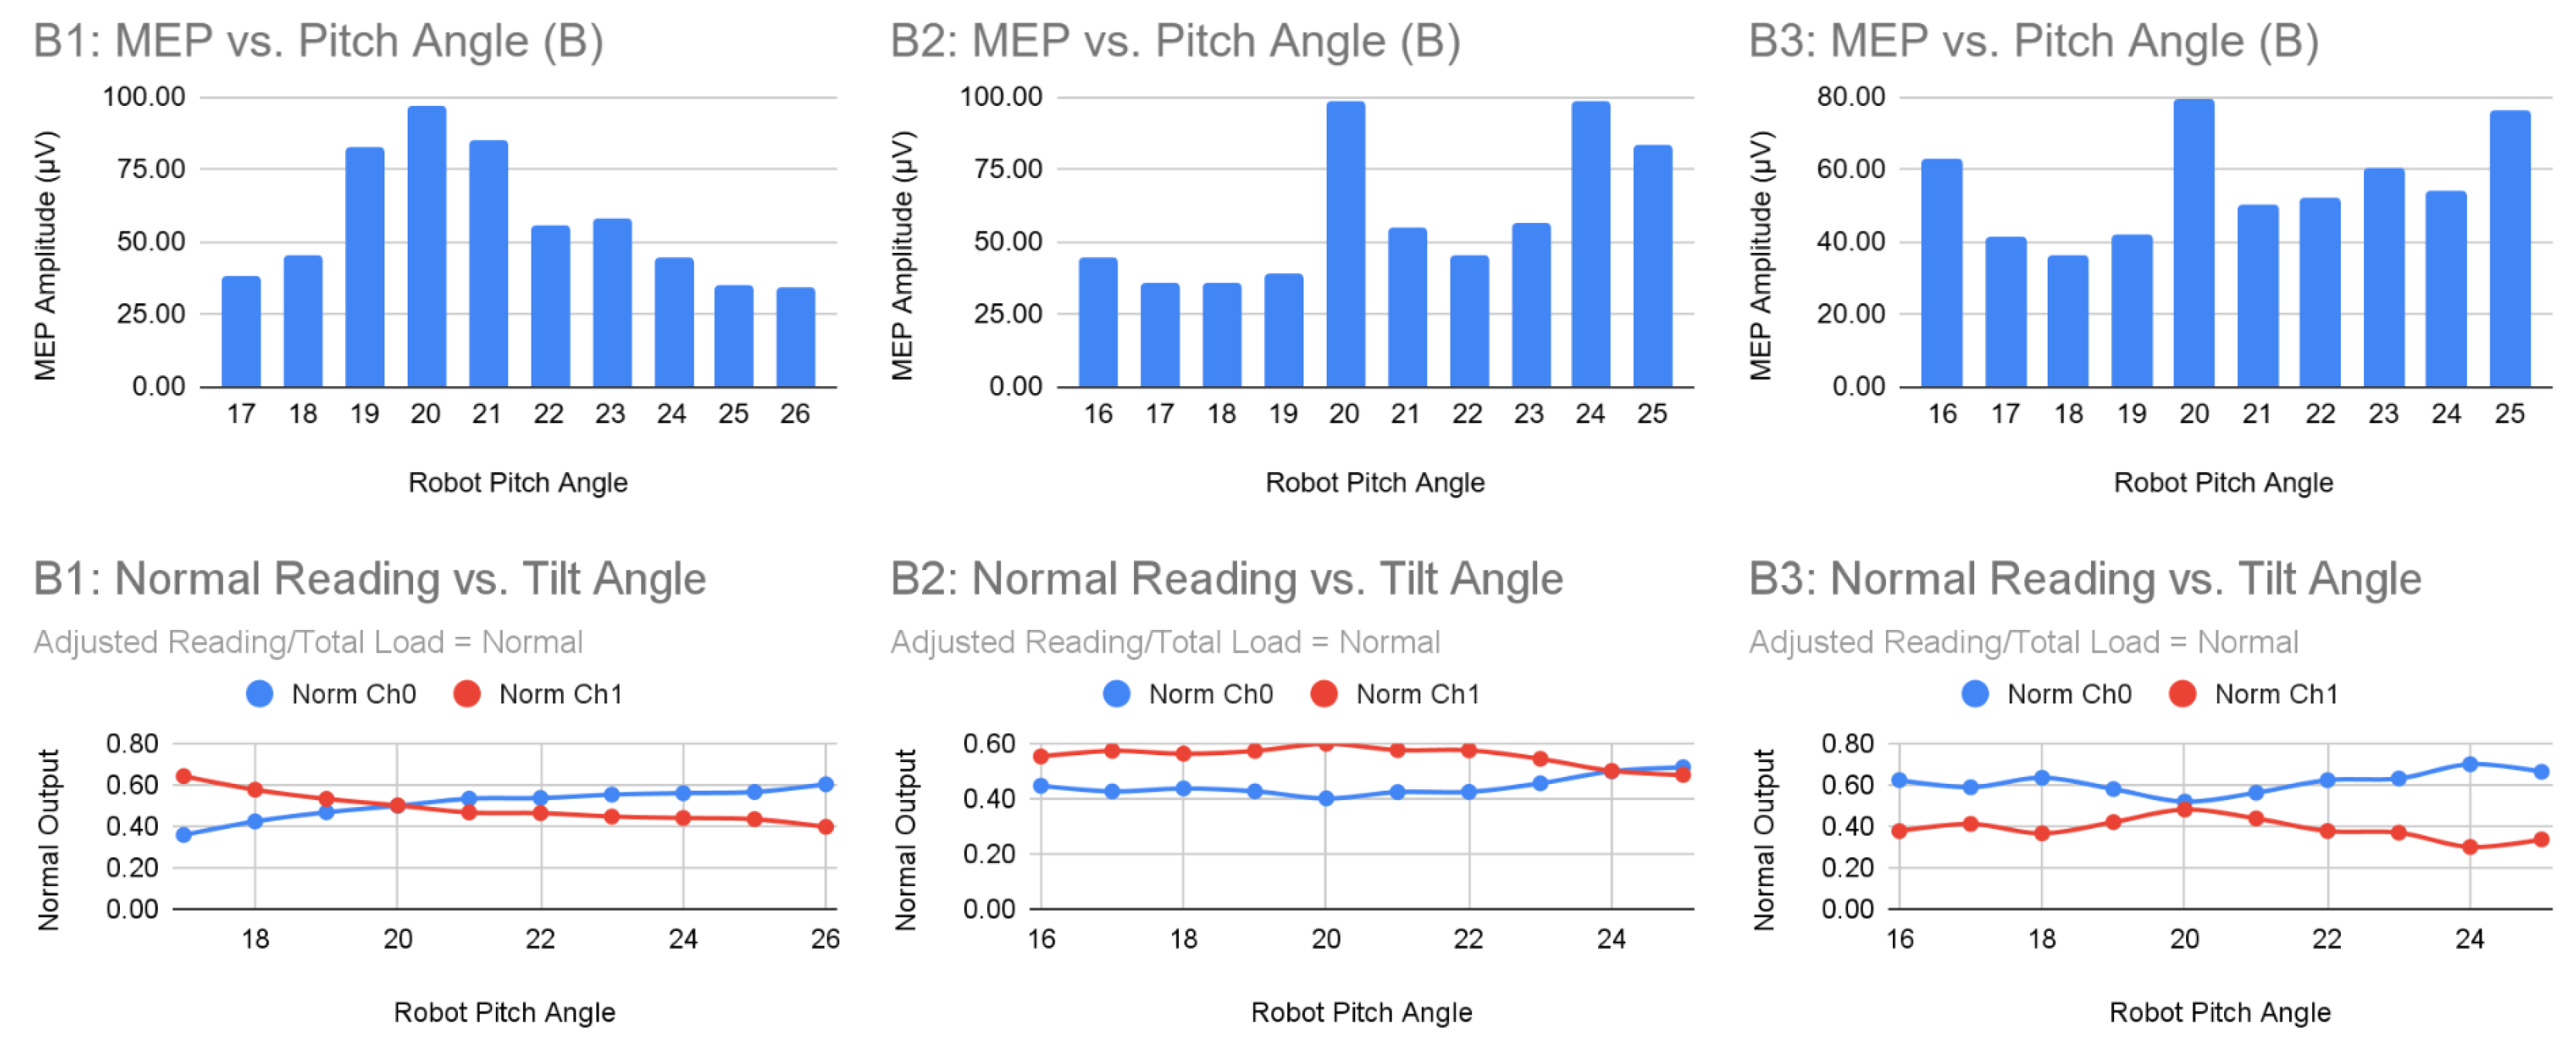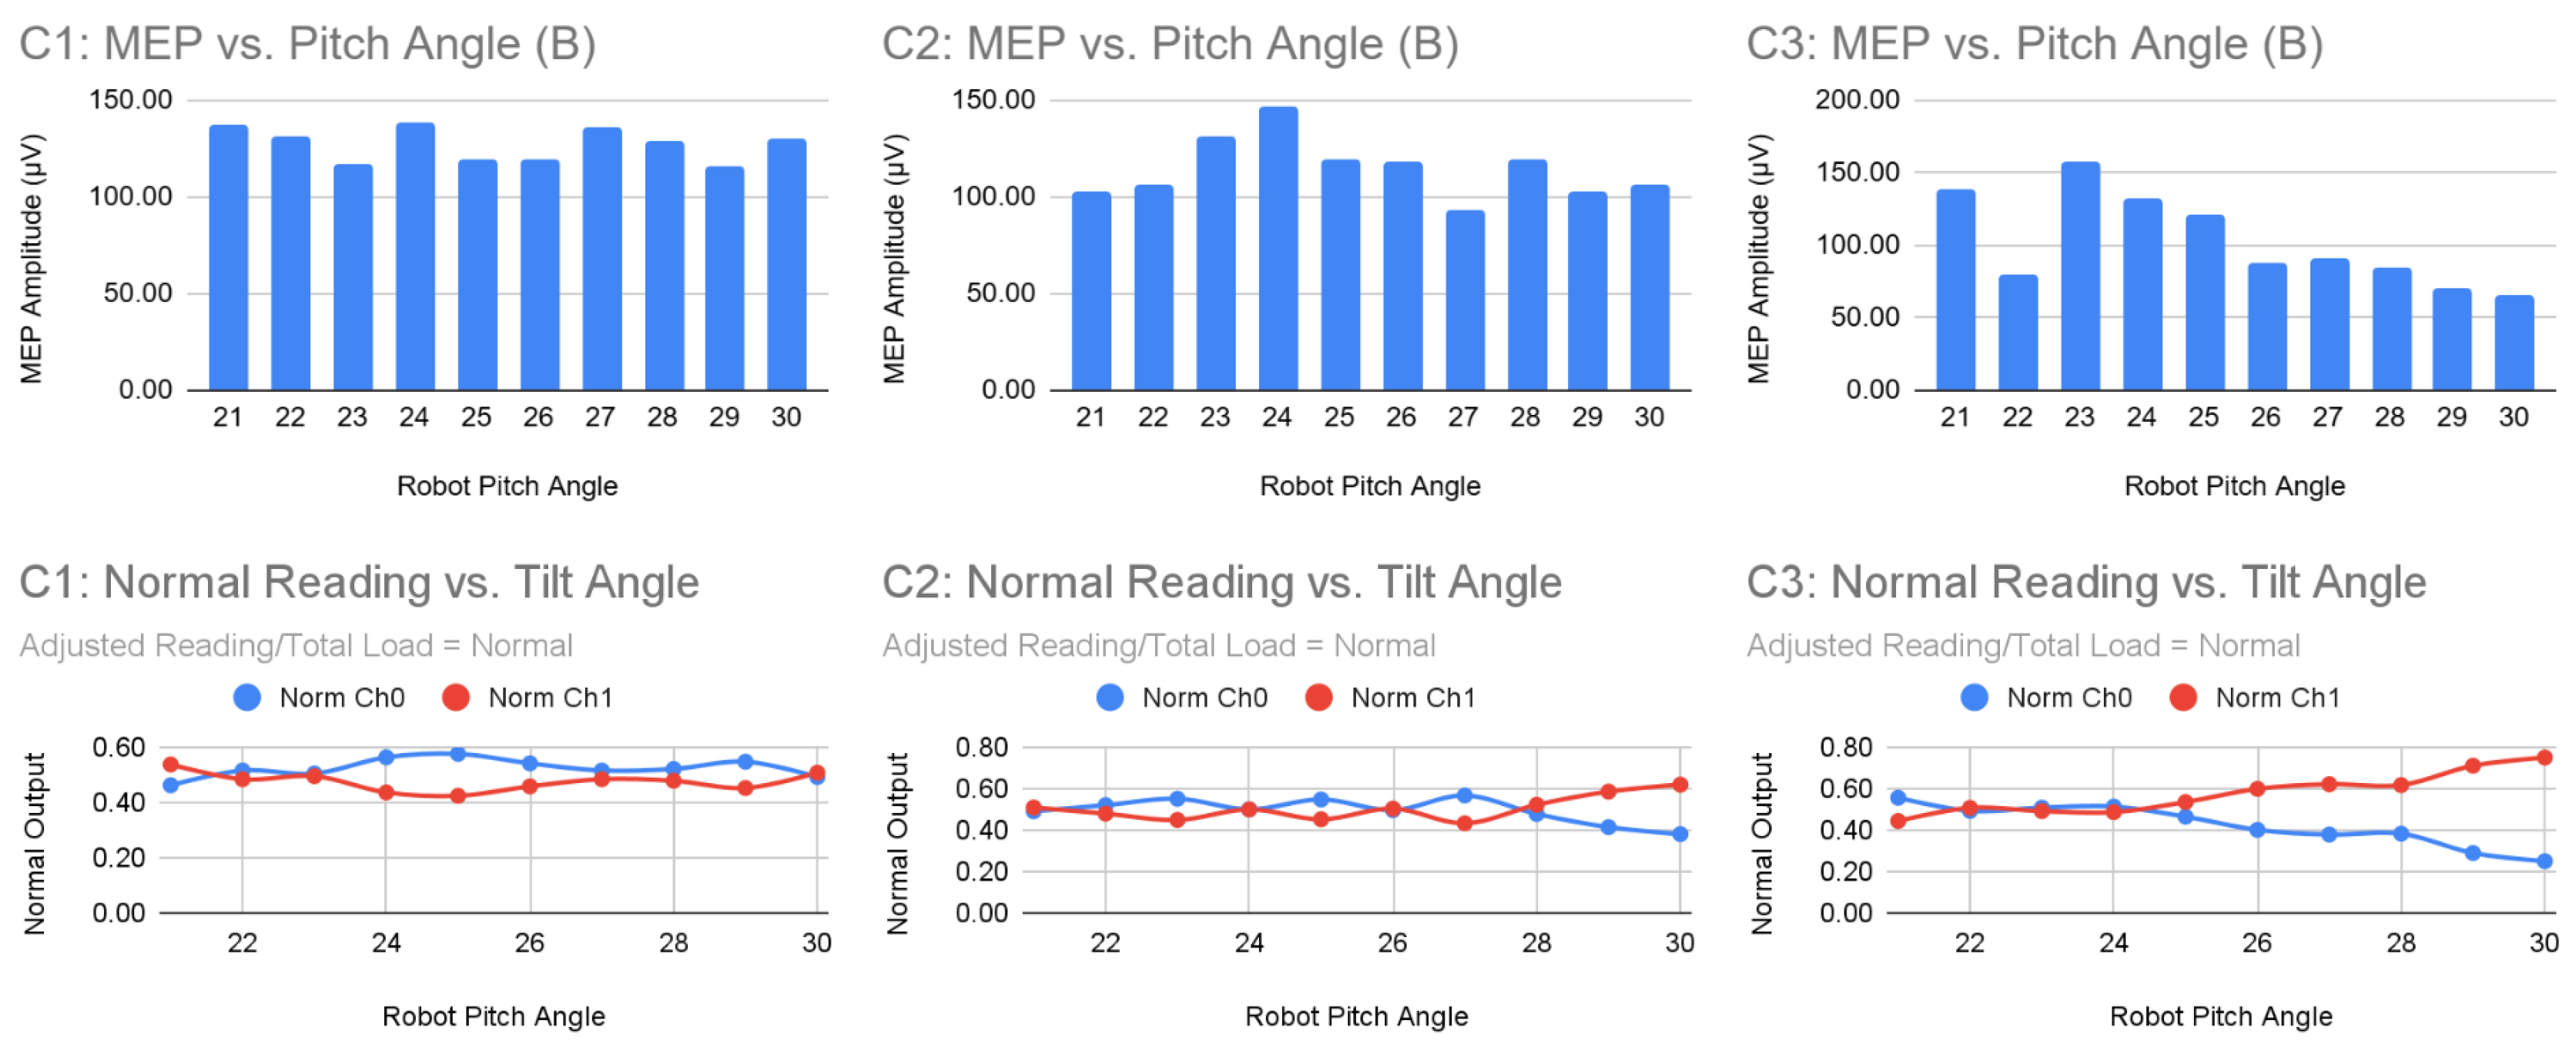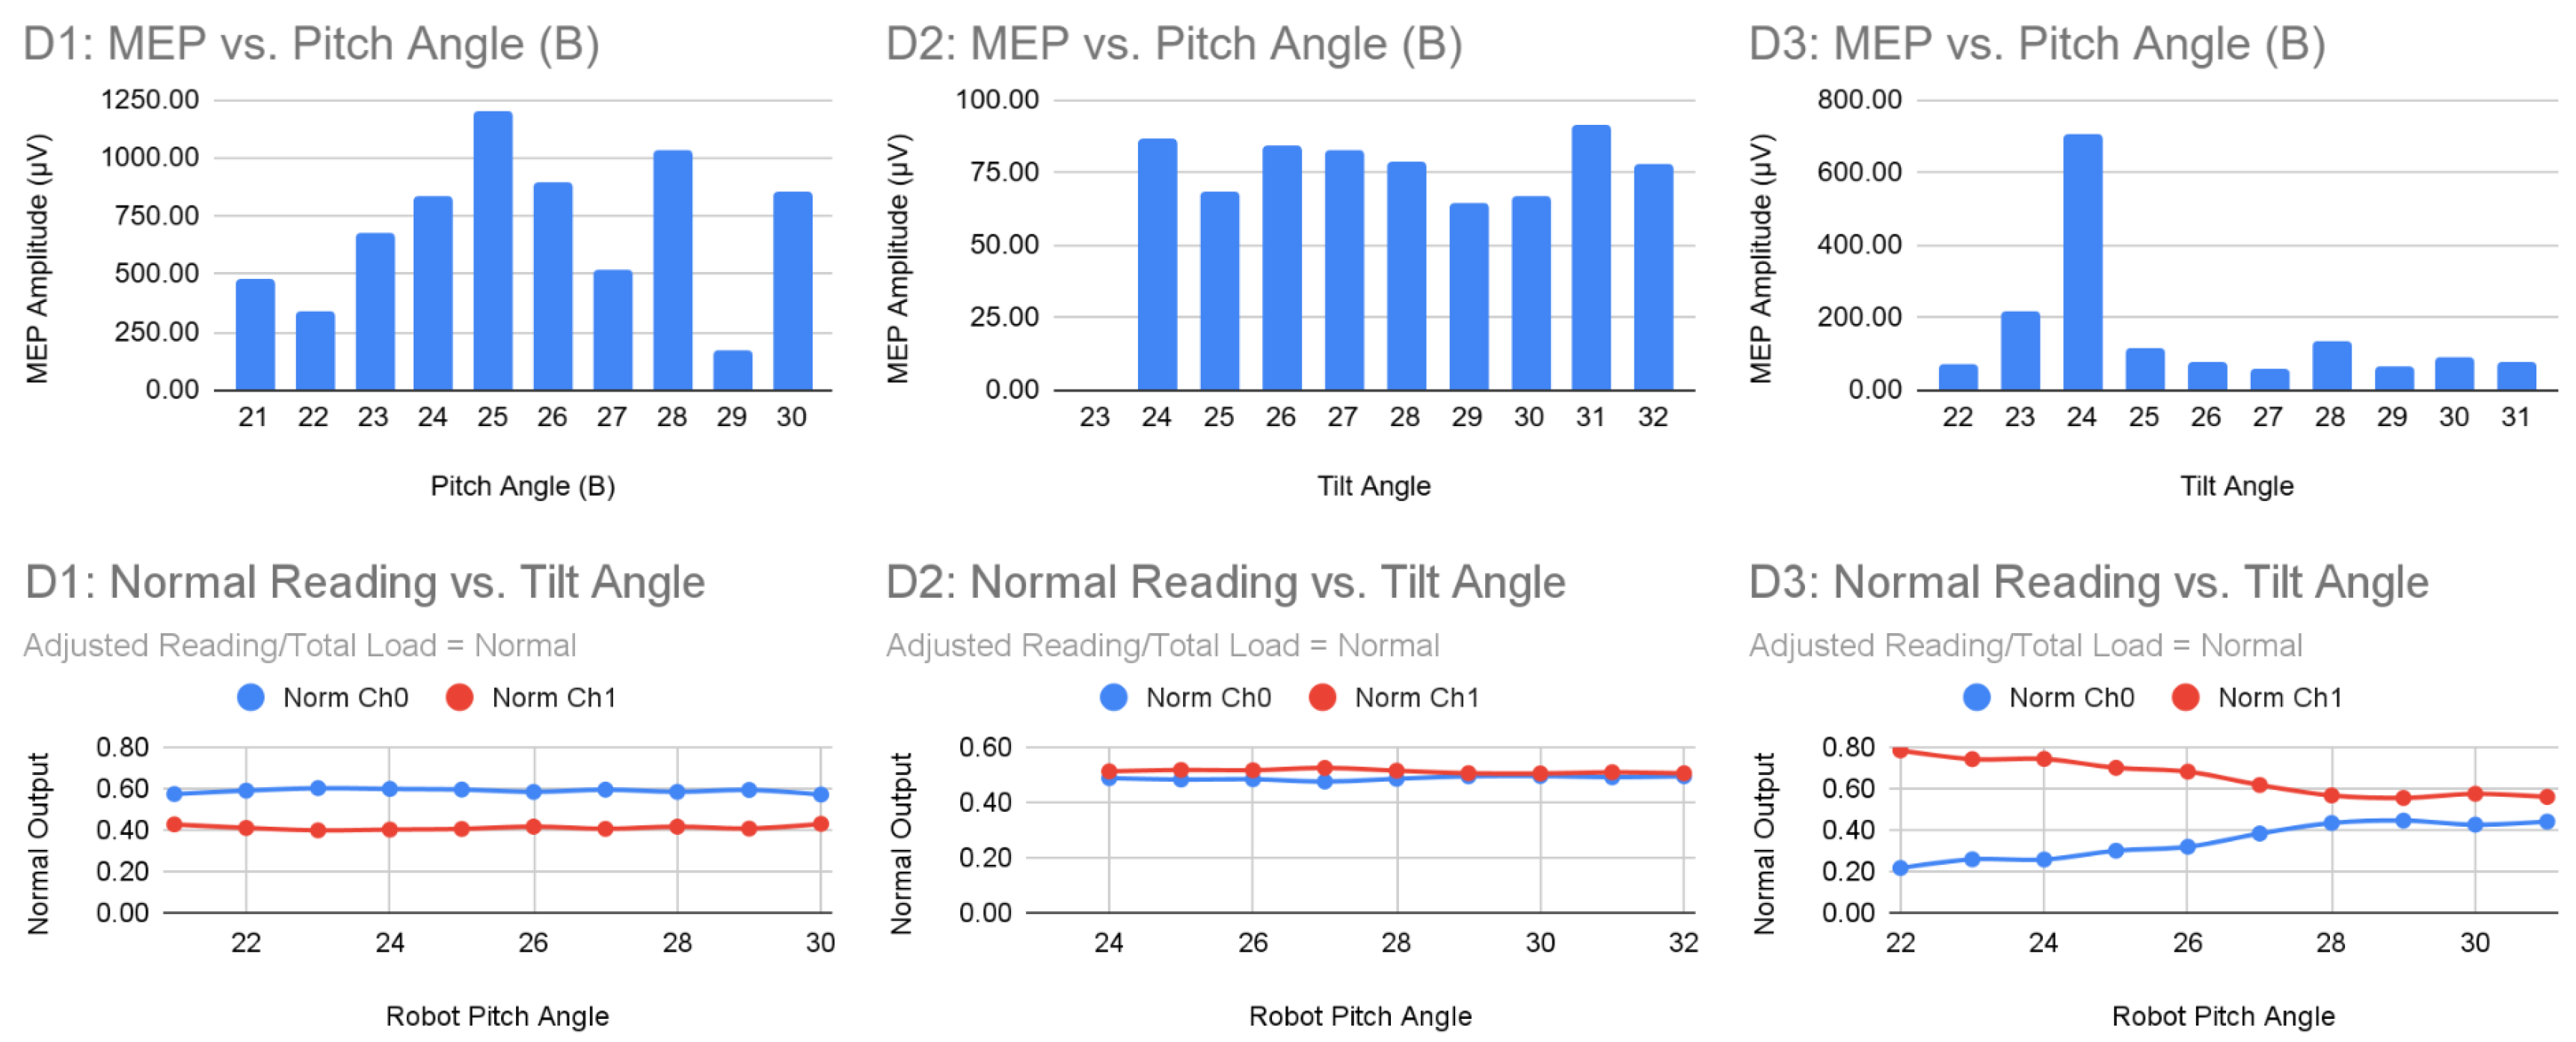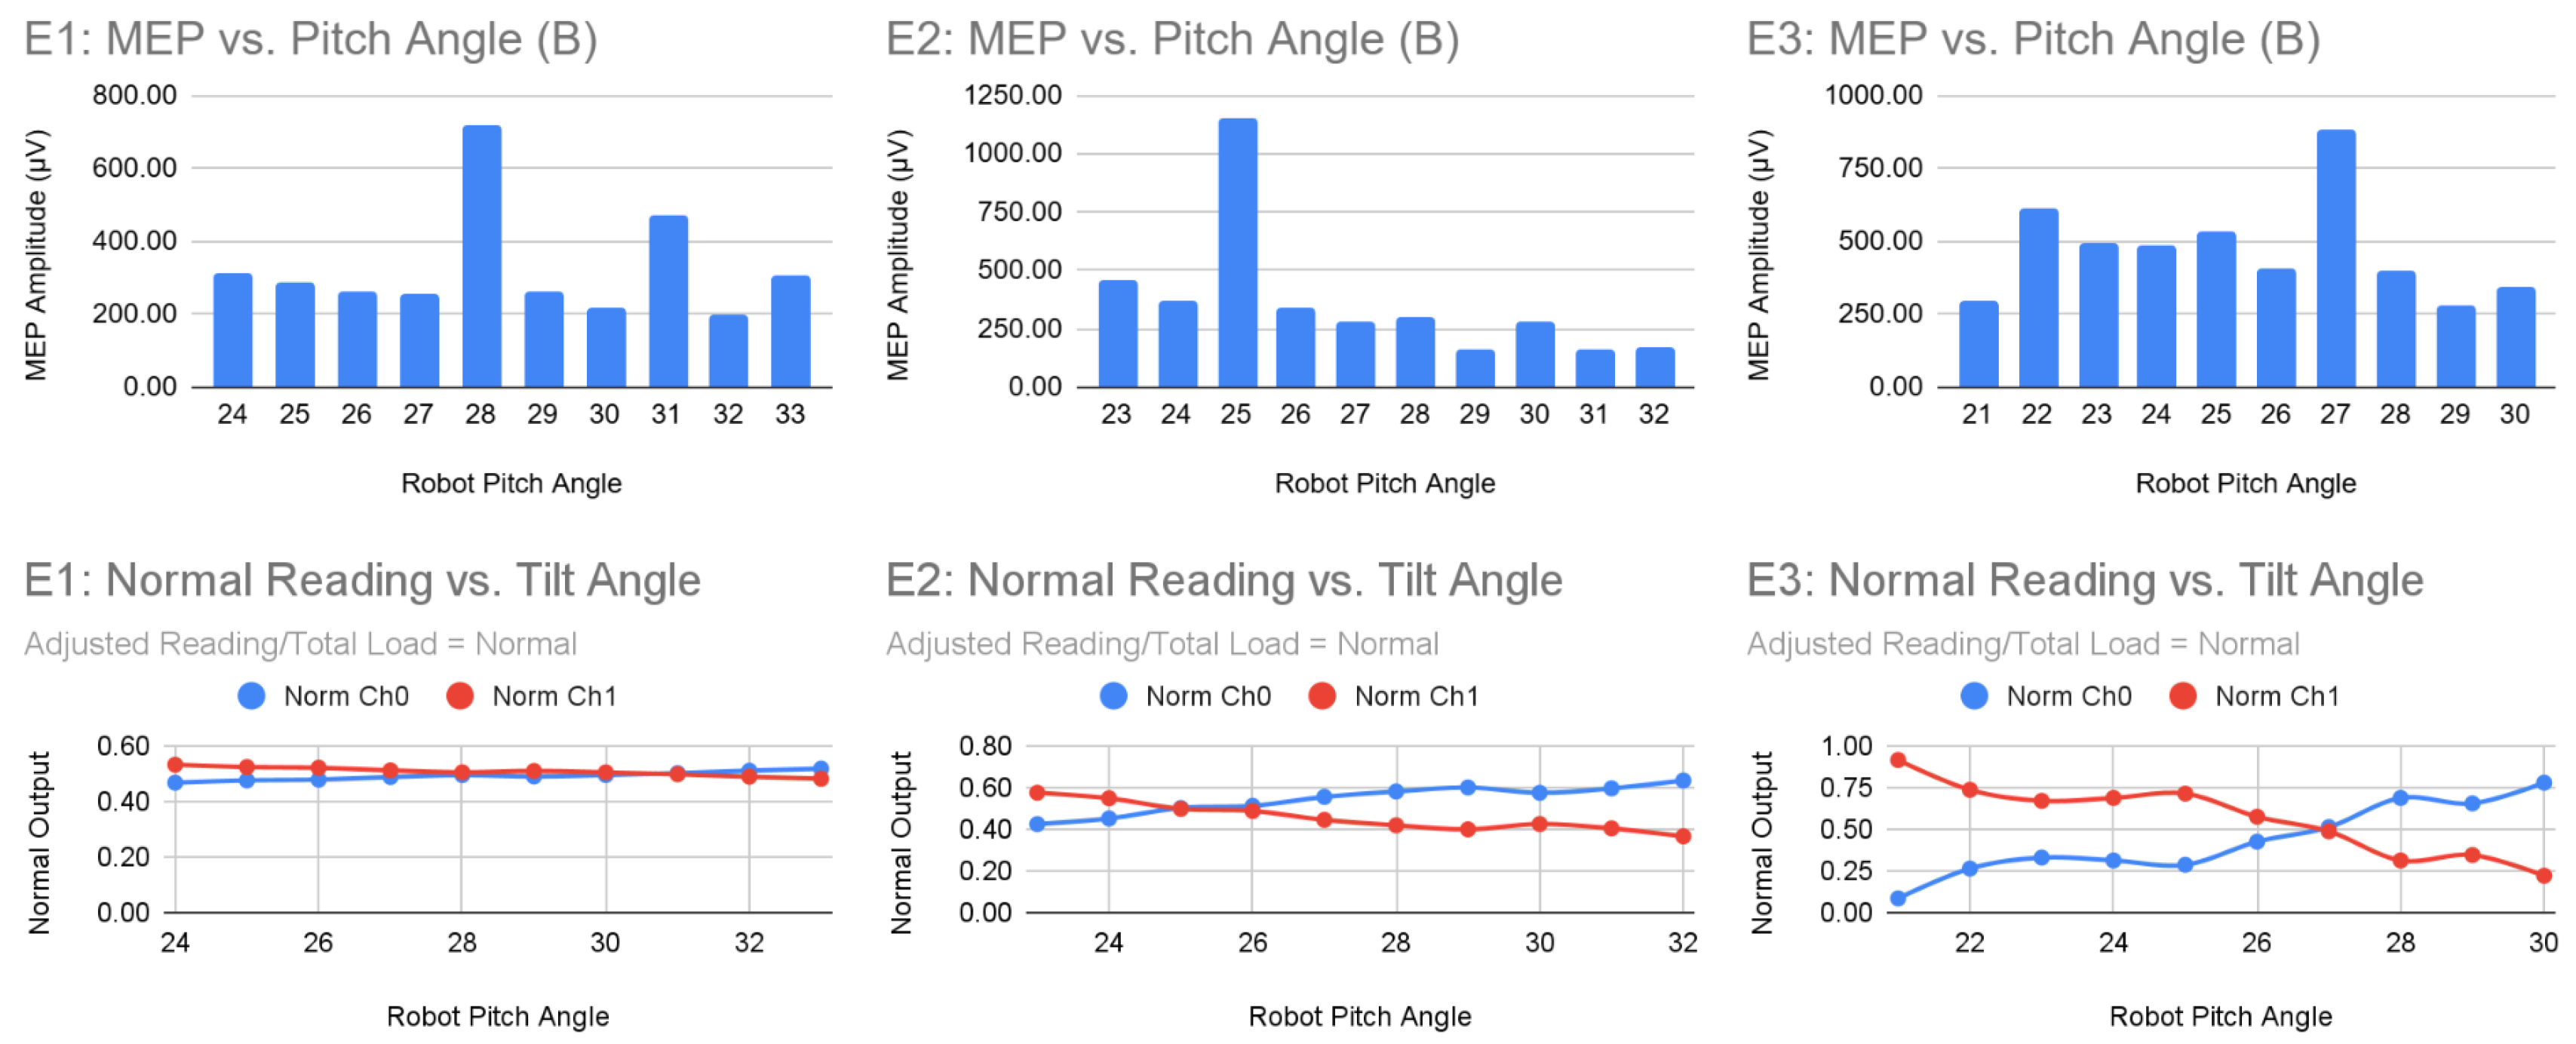
Development of a Robot-Assisted TMS Localization System Using Dual Capacitive Sensors for Coil Tilt Detection
 , , , , and
Highlights
- A robotic-assisted TMS system using a 3D camera to detect facial landmarks can successfully locate the C3 motor hotspot with minimal calibration.
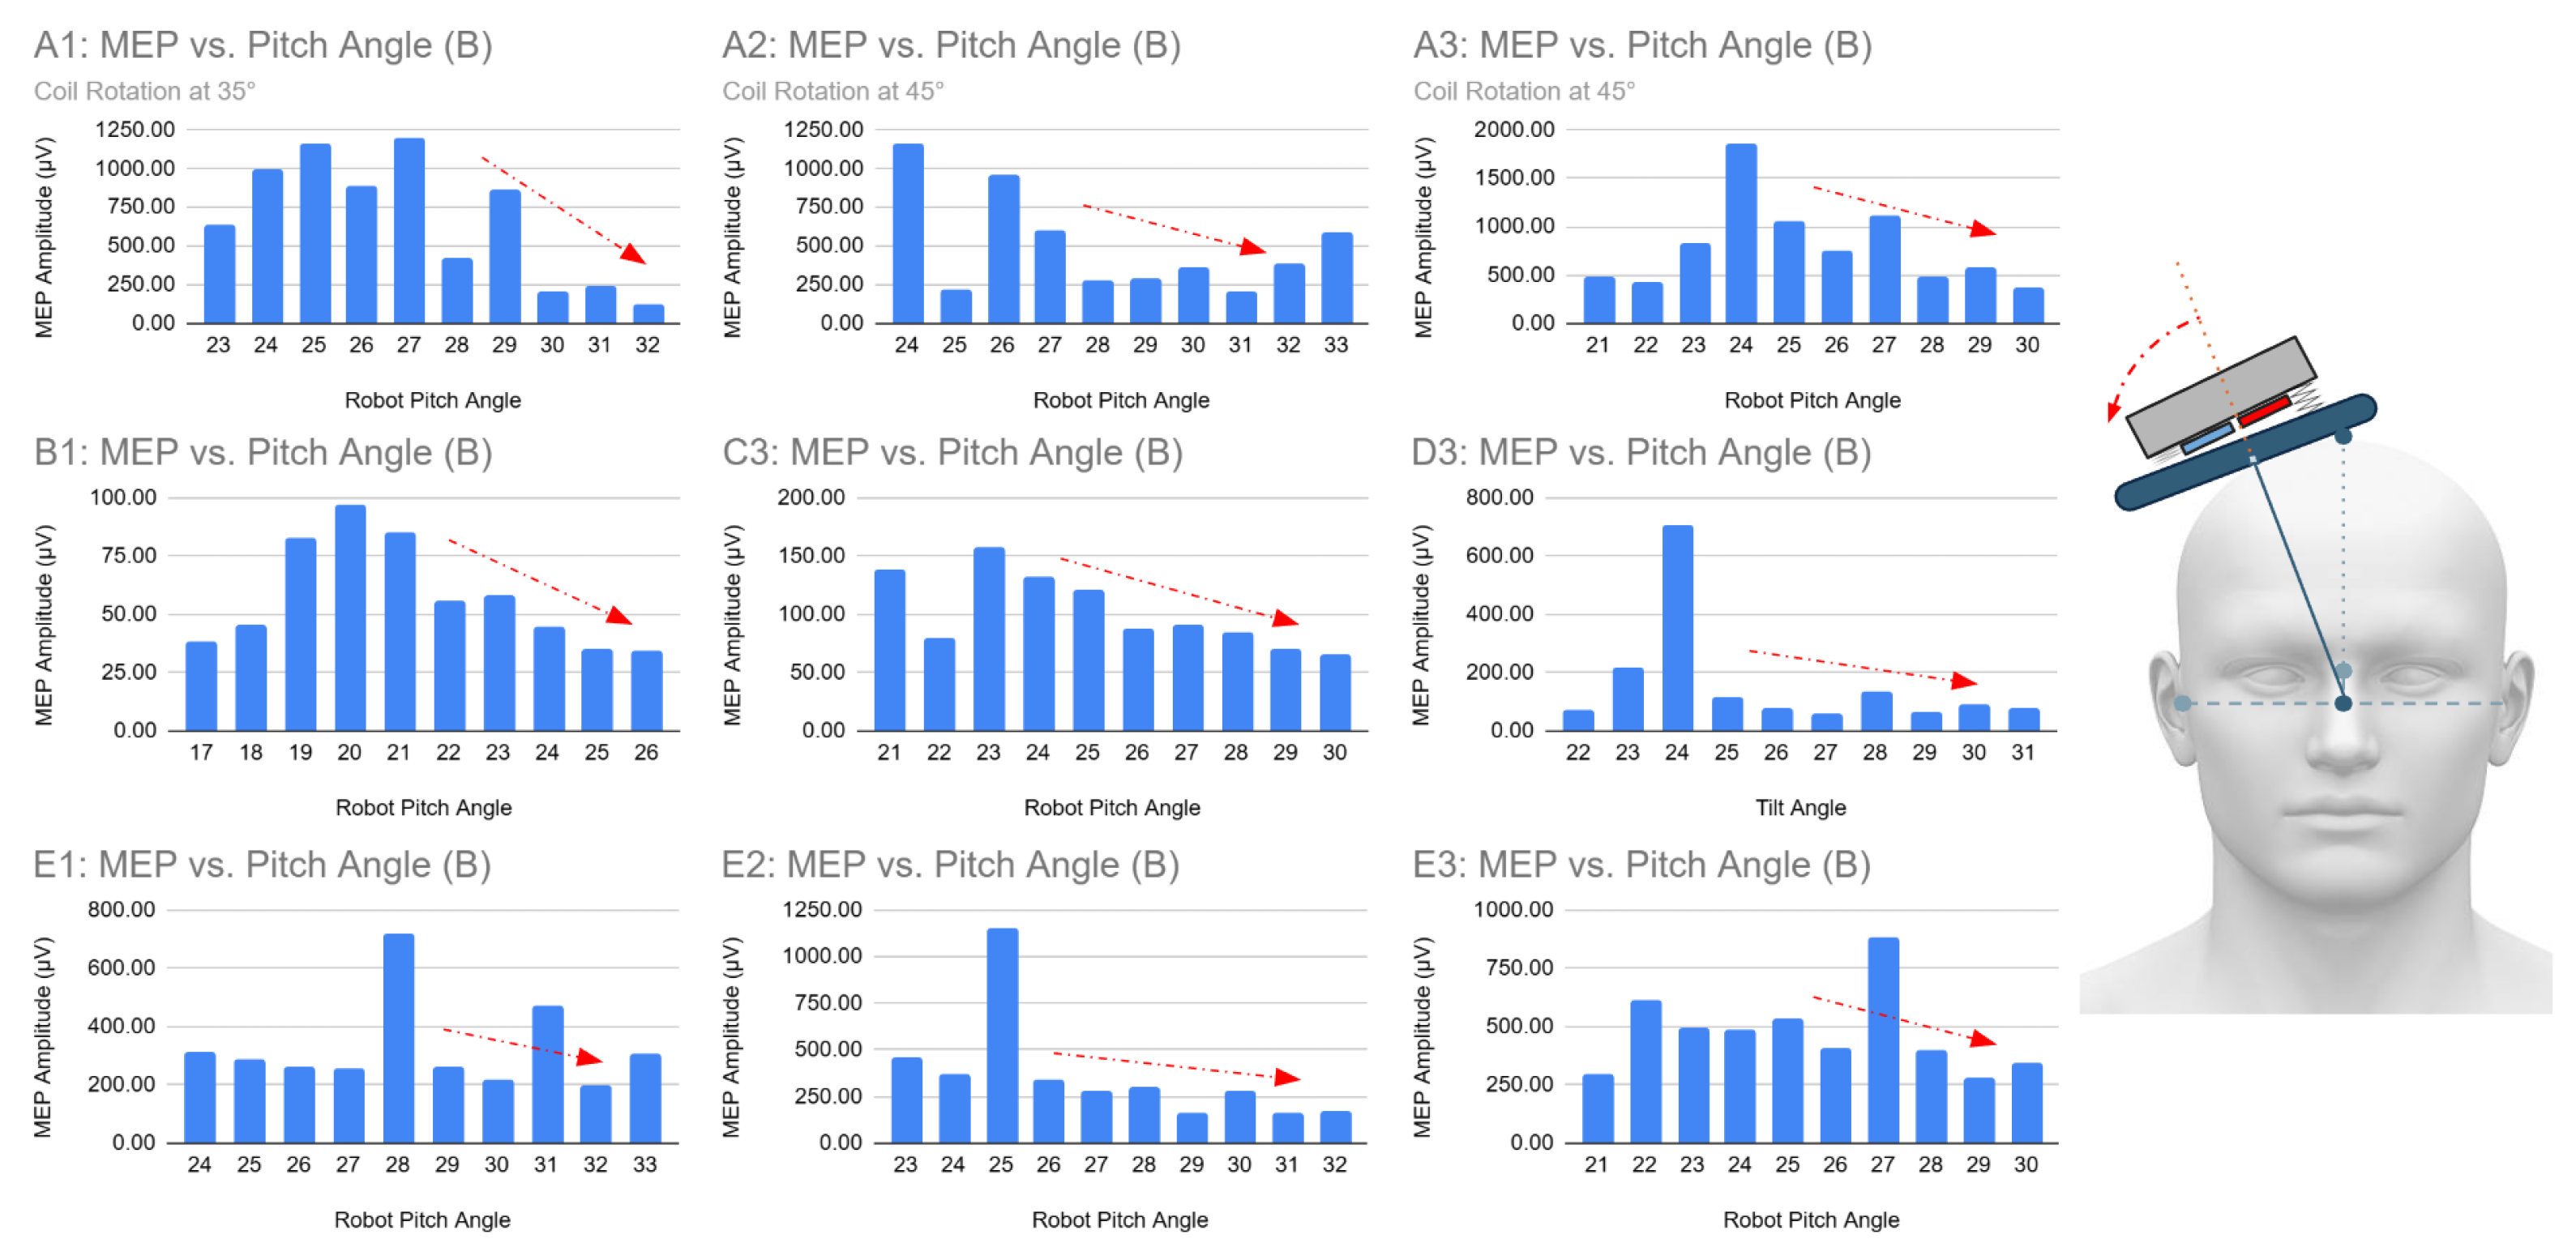
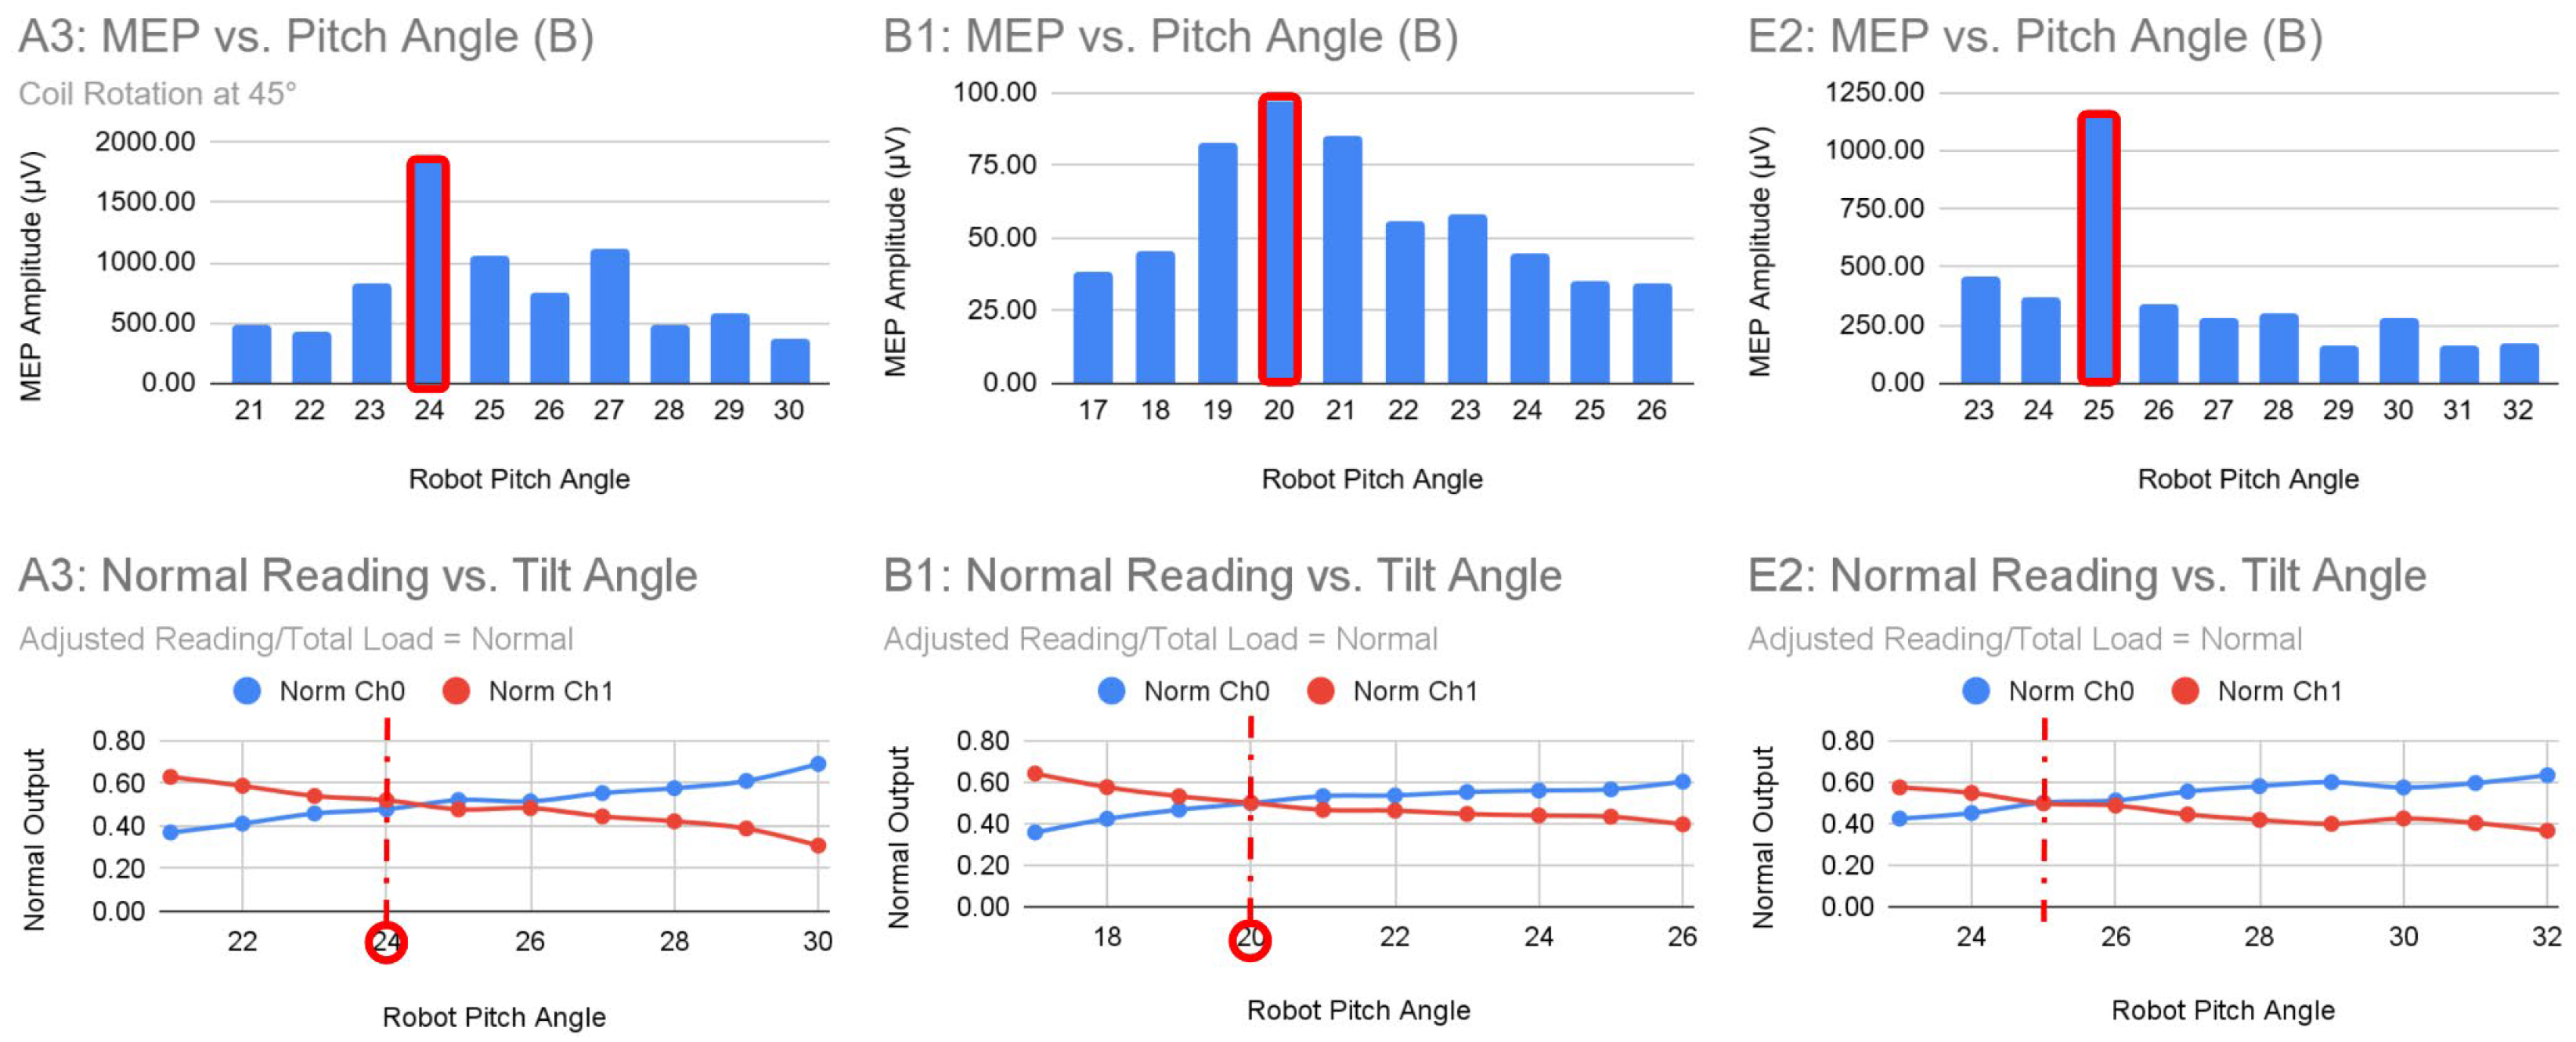
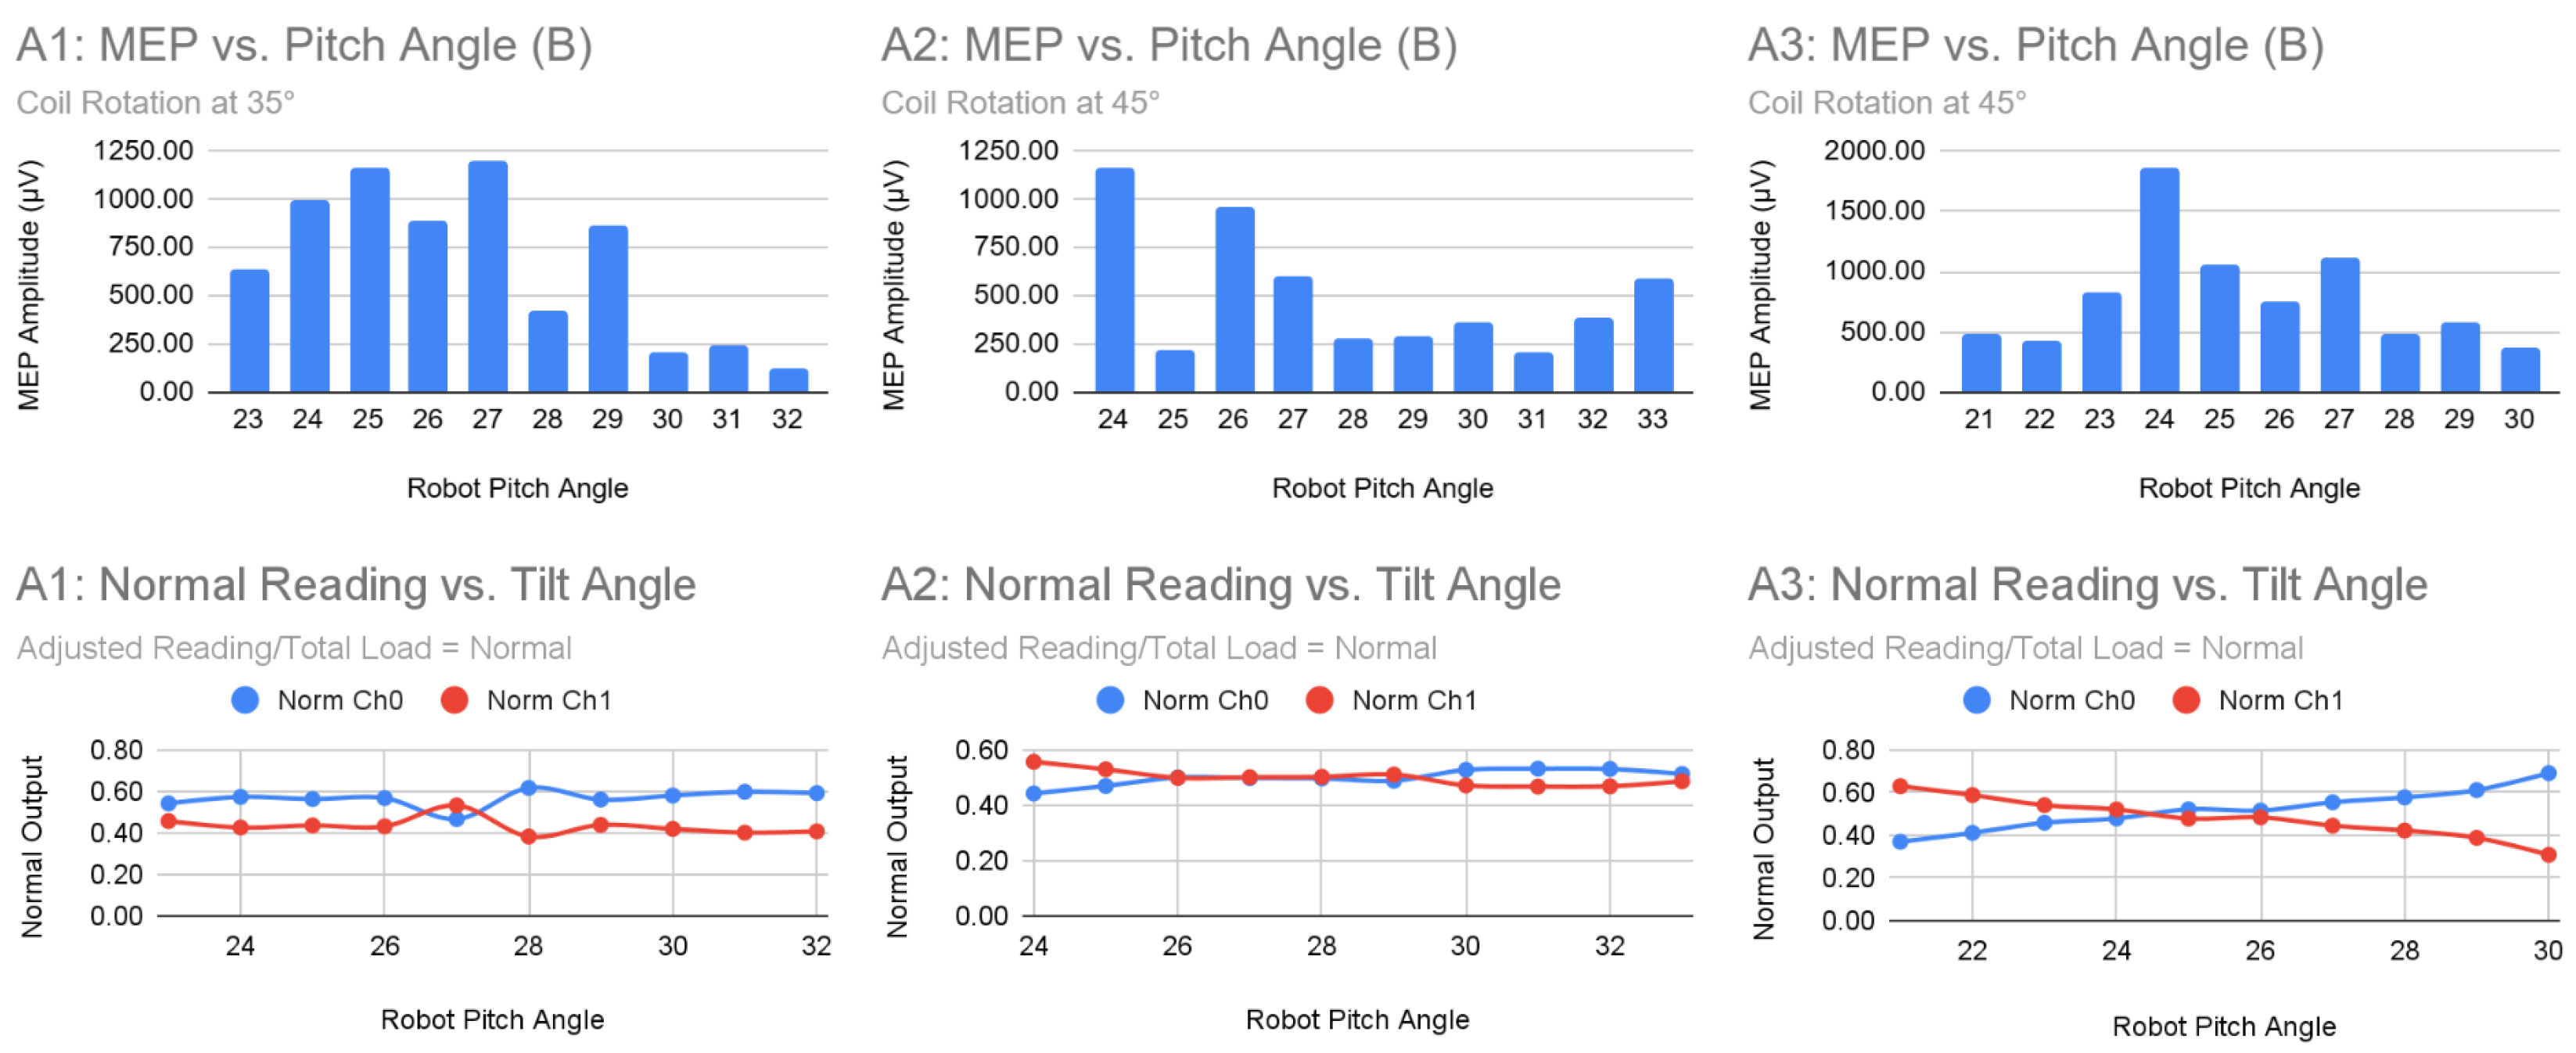
- Sensor ratio balance and moderate contact pressure result in higher MEP amplitudes, indicating effective coil–scalp alignment and tilt detection.
- Low-cost textile capacitive sensors are able to provide real-time feedback on coil positioning and tilt, enabling safer and more reproducible TMS procedures.
- Robotic assistance has the potential to reduce setup time and operator dependency compared to traditional manual localization, improving efficiency and consistency in clinical and research settings.
Abstract
1. Introduction
2. Materials and Methods
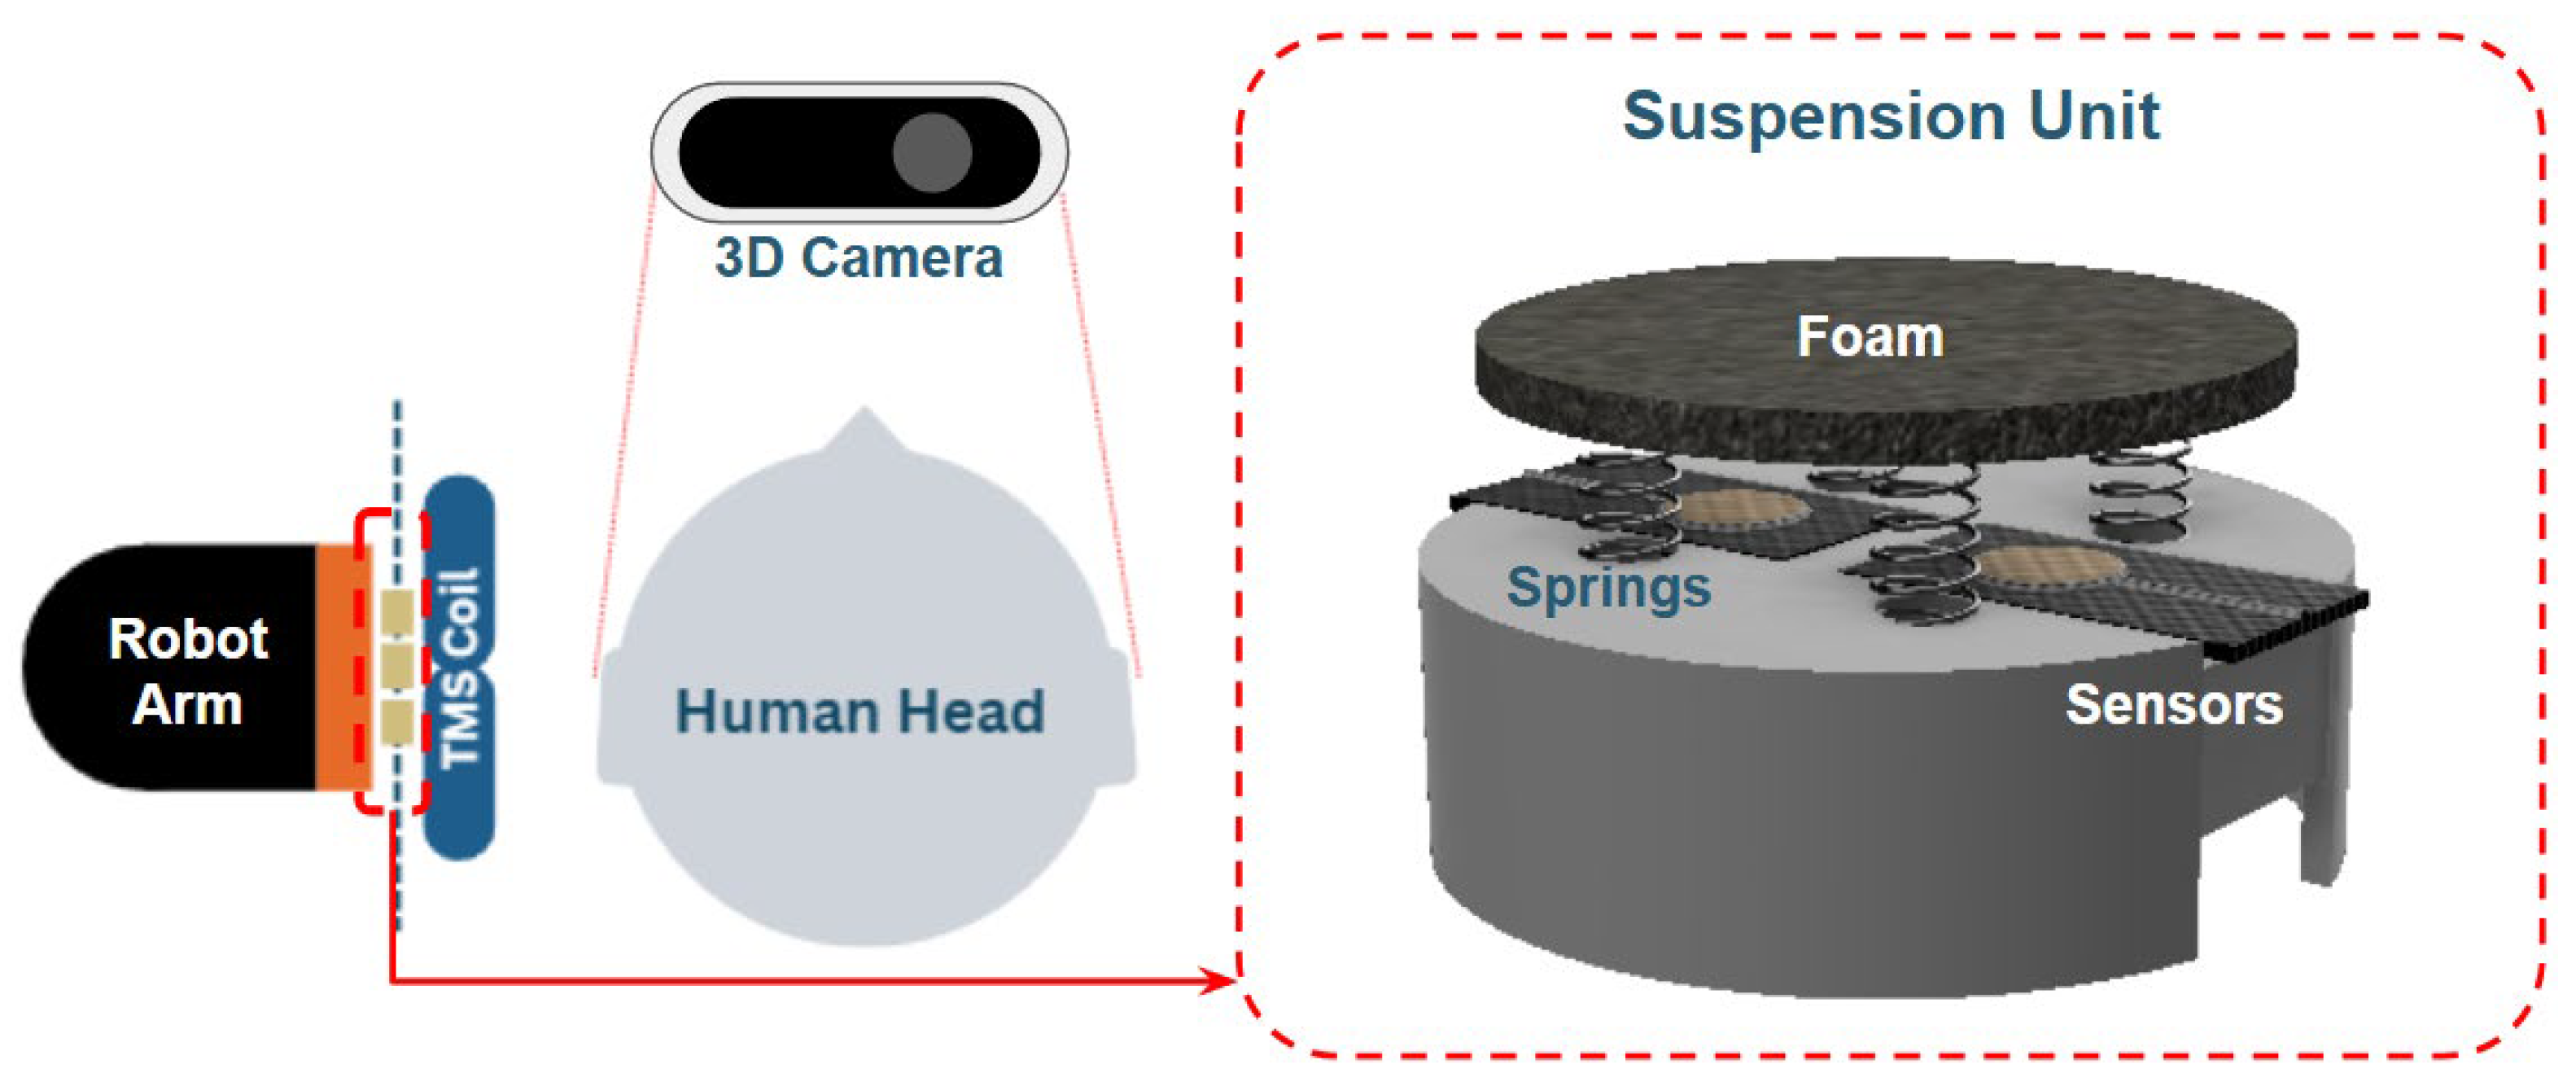
2.1. System Overview
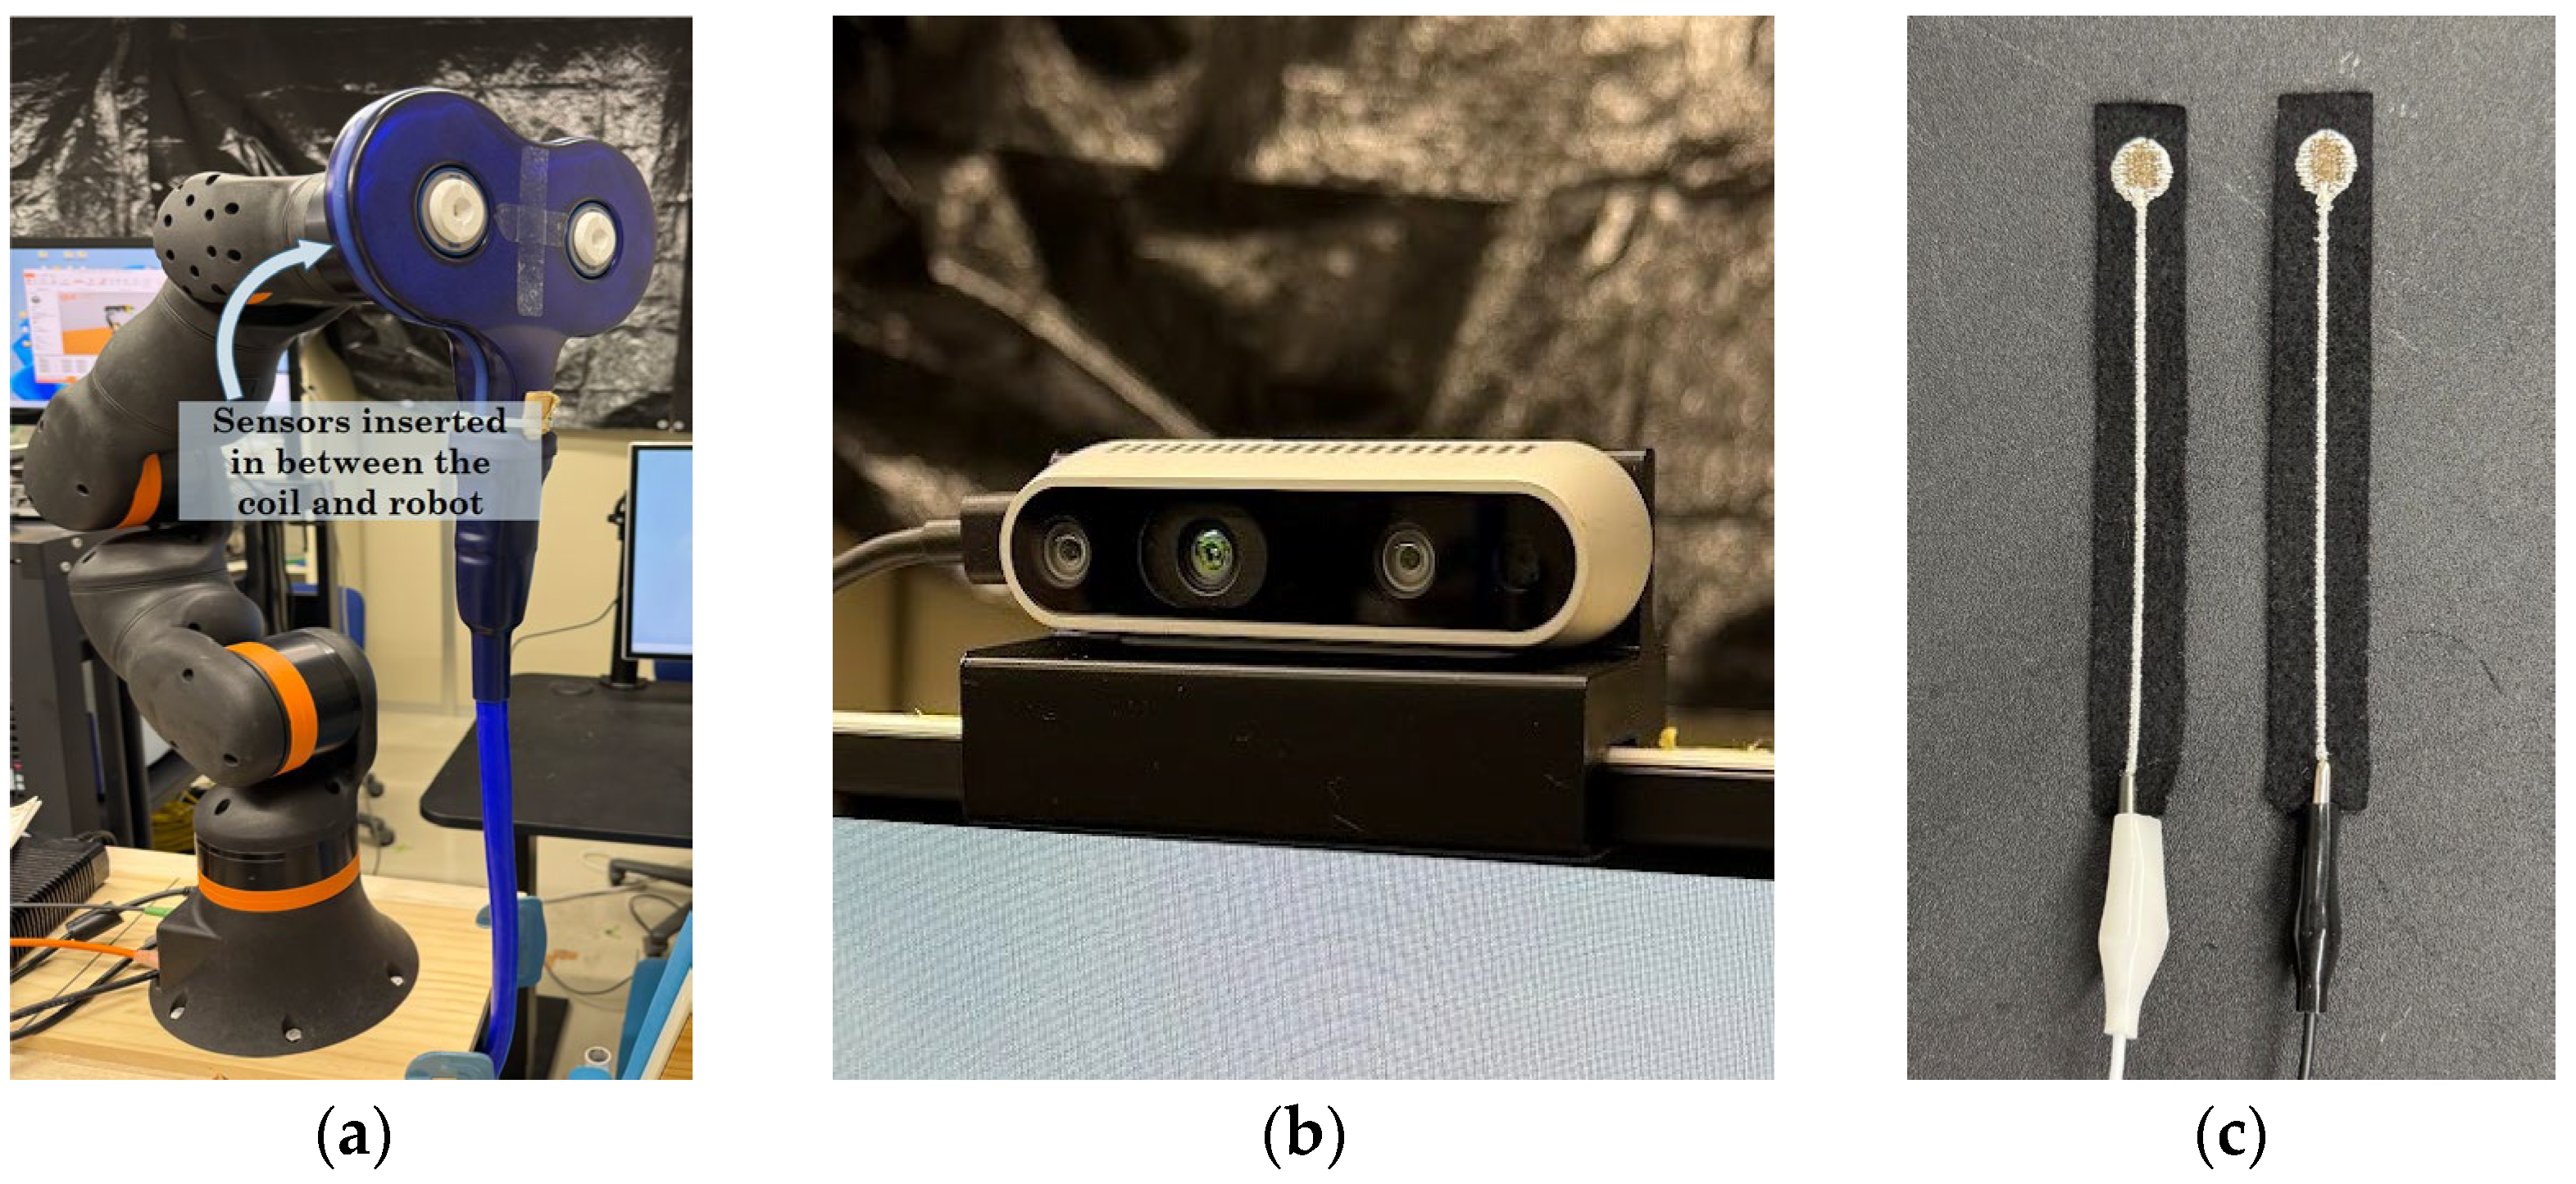
2.2. Hardware Configuration
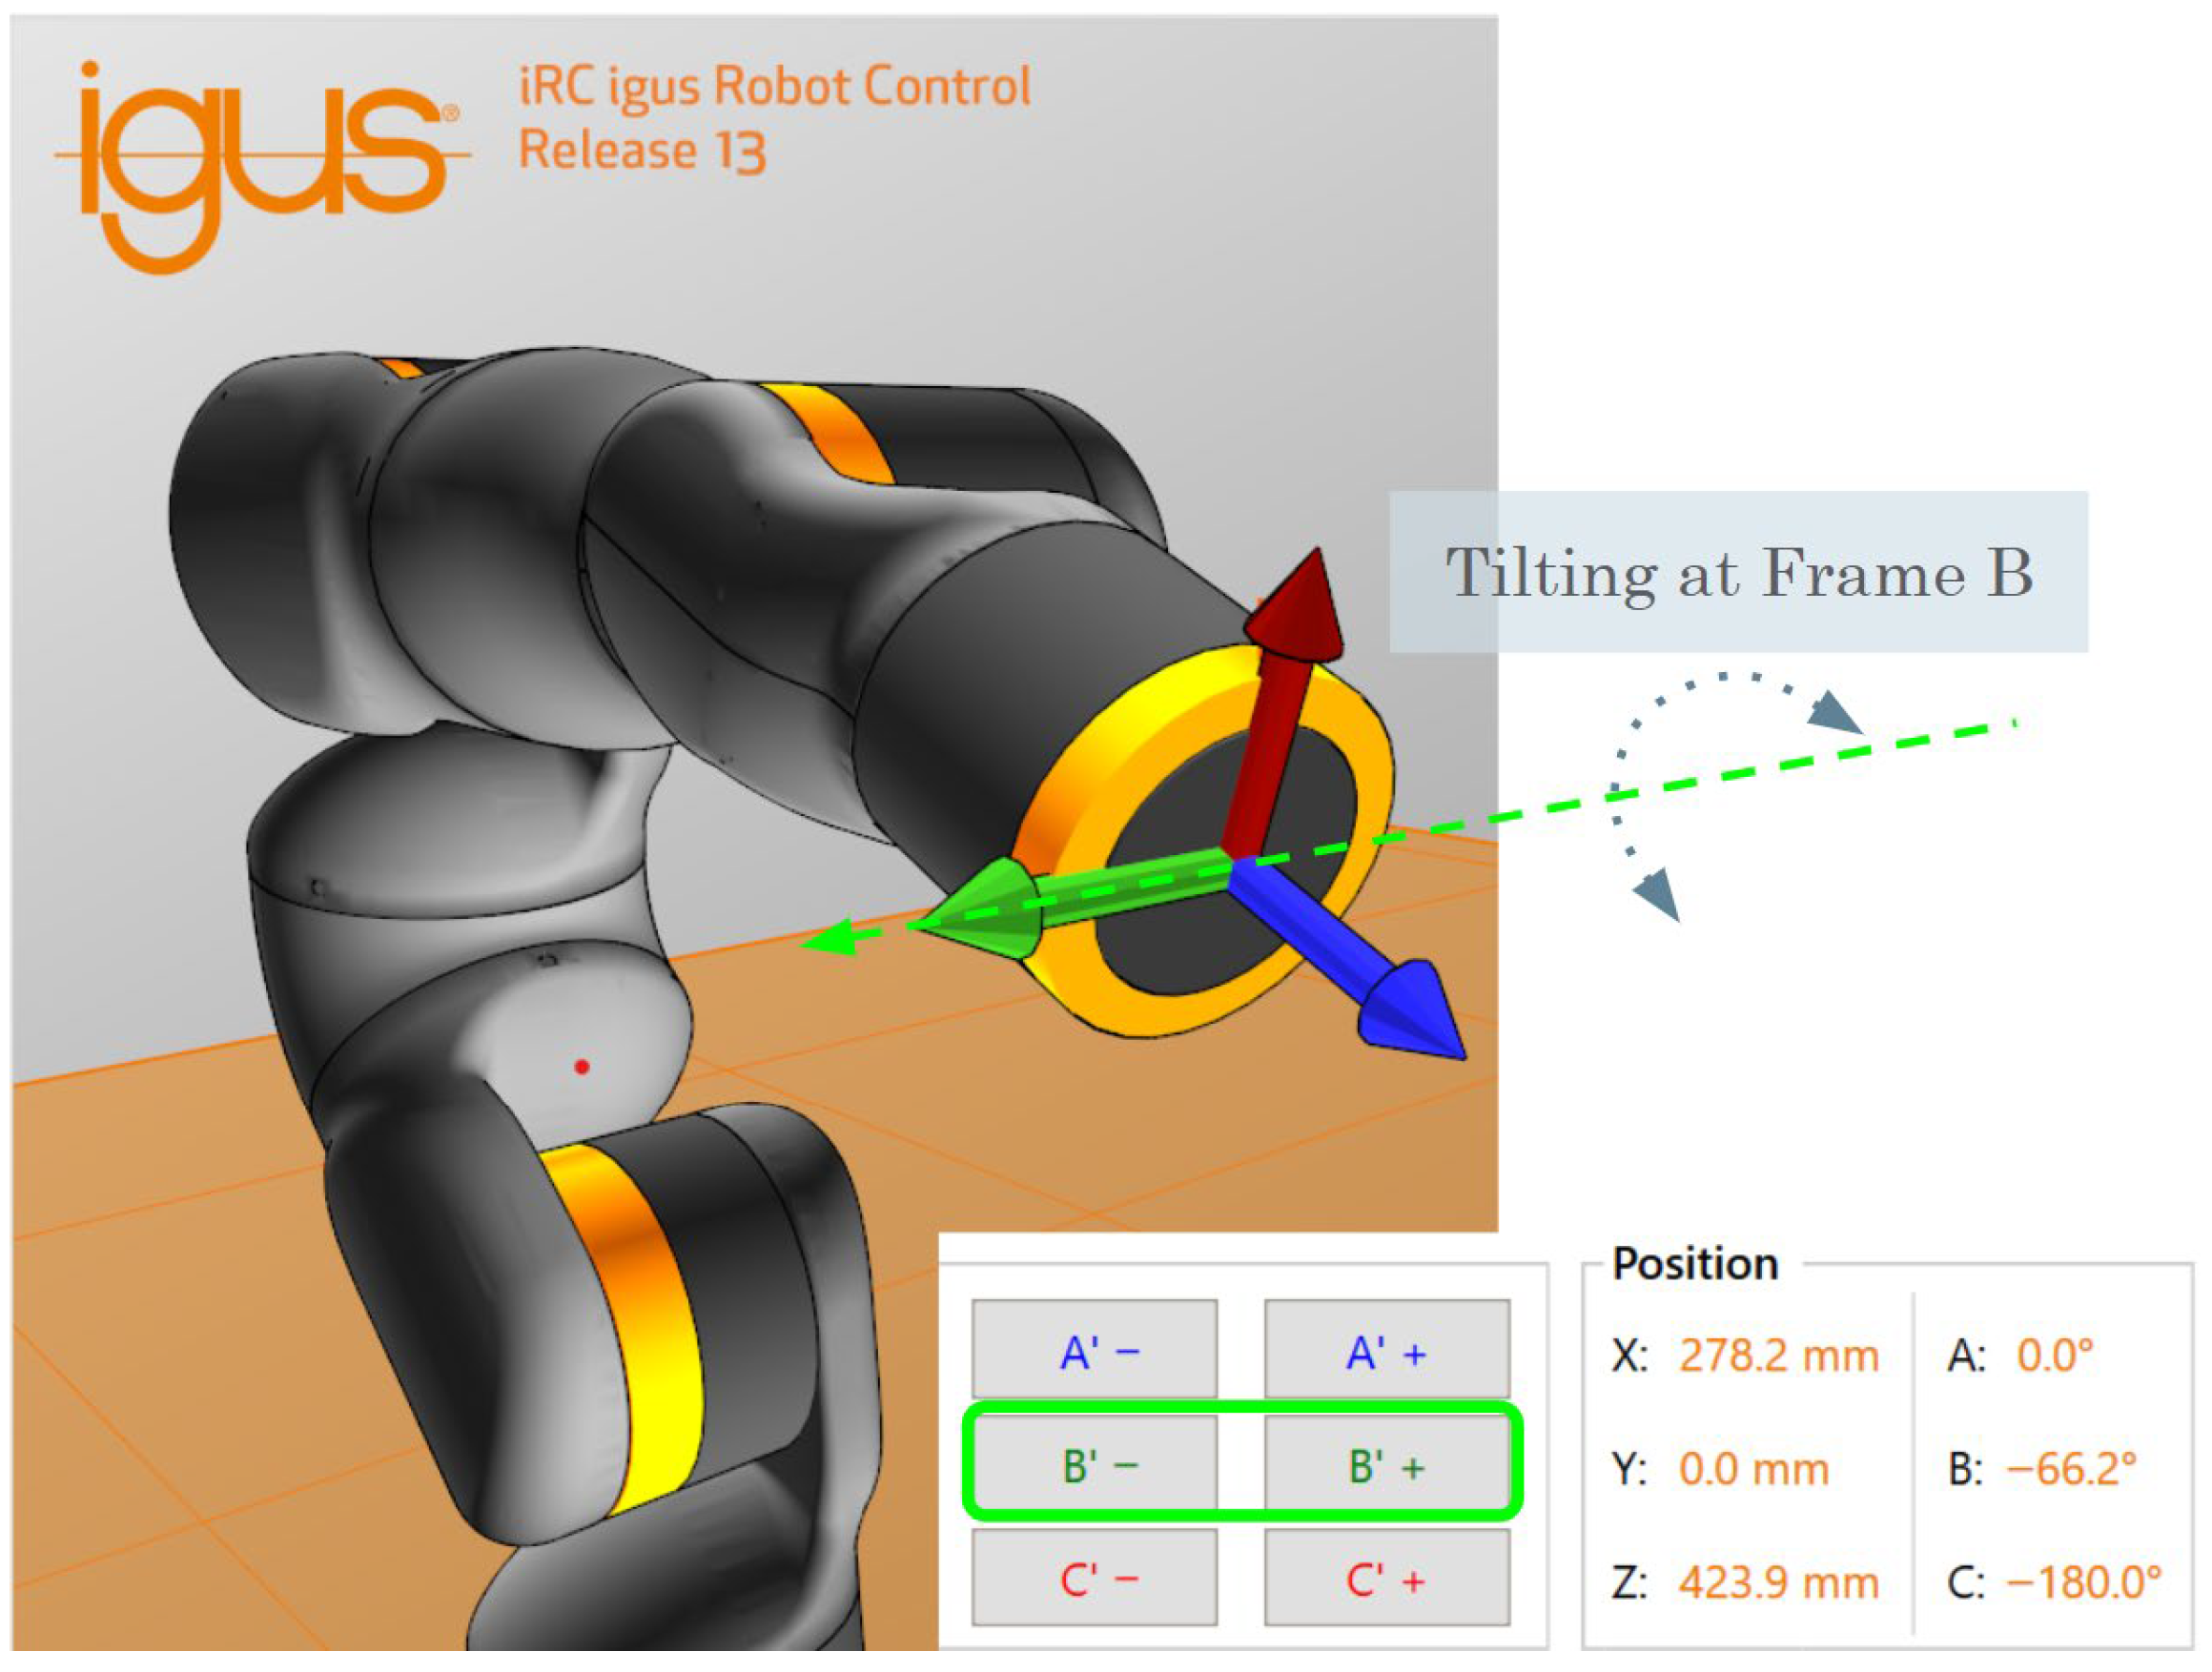
2.2.1. igus ReBeL 5-DOF Cobot
2.2.2. Textile Capacitive Sensors
- A 50-sample baseline for each sensor is collected for calibration
- Baseline is subtracted from real-time reading (capacitance count):
- Normalized ratio between the two sensors is computed:
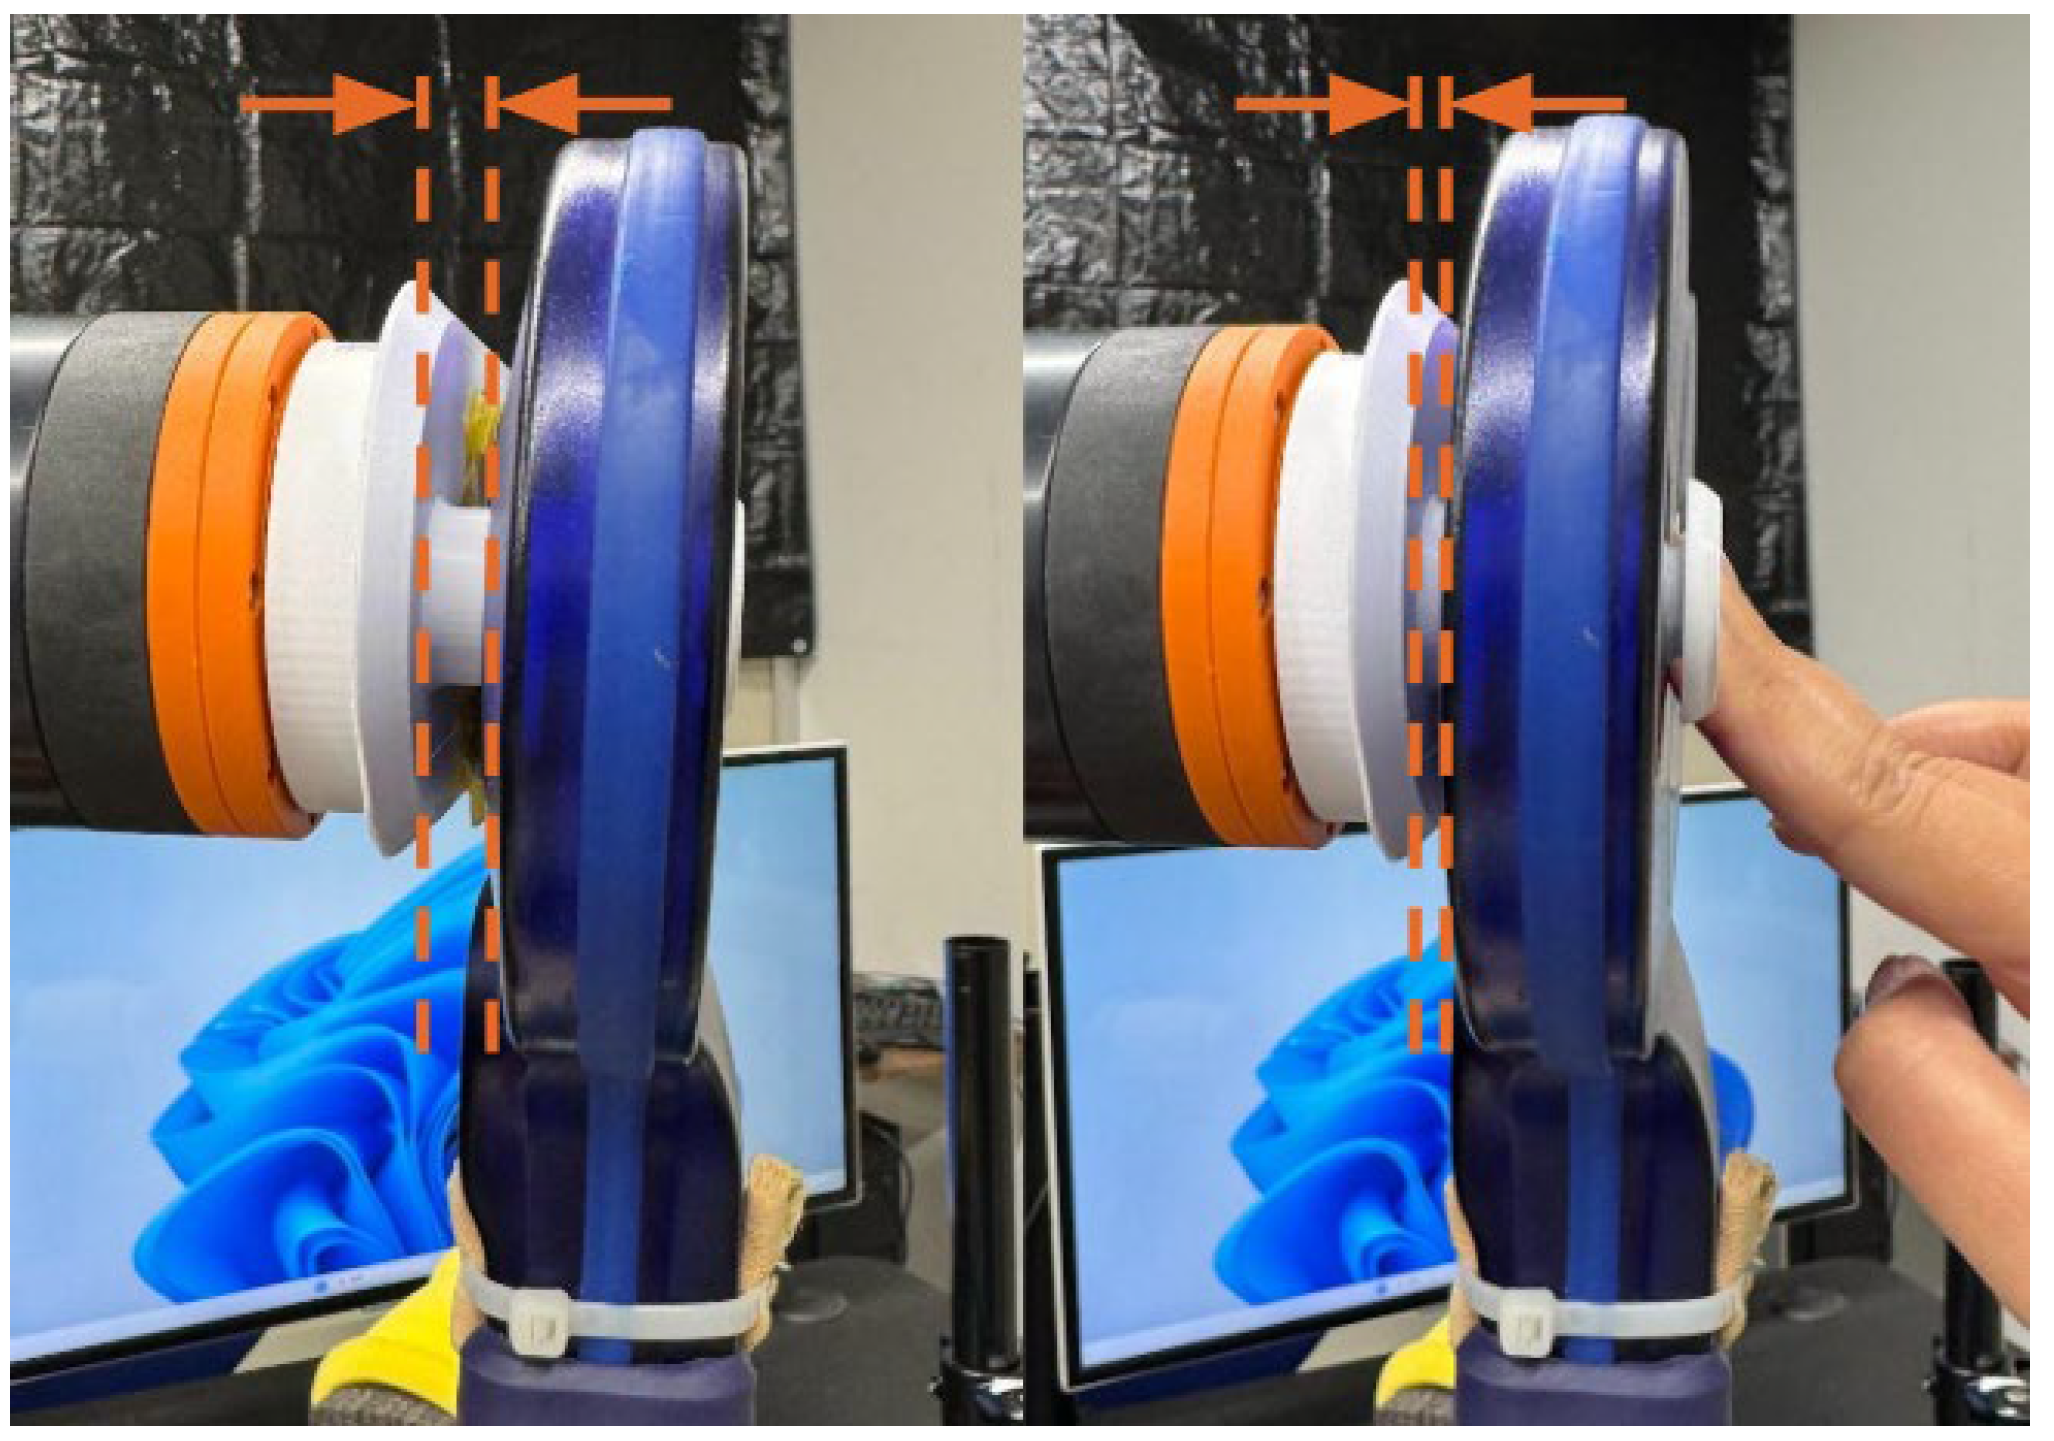
2.2.3. Suspension System
2.3. Software Architecture and C3 Localization
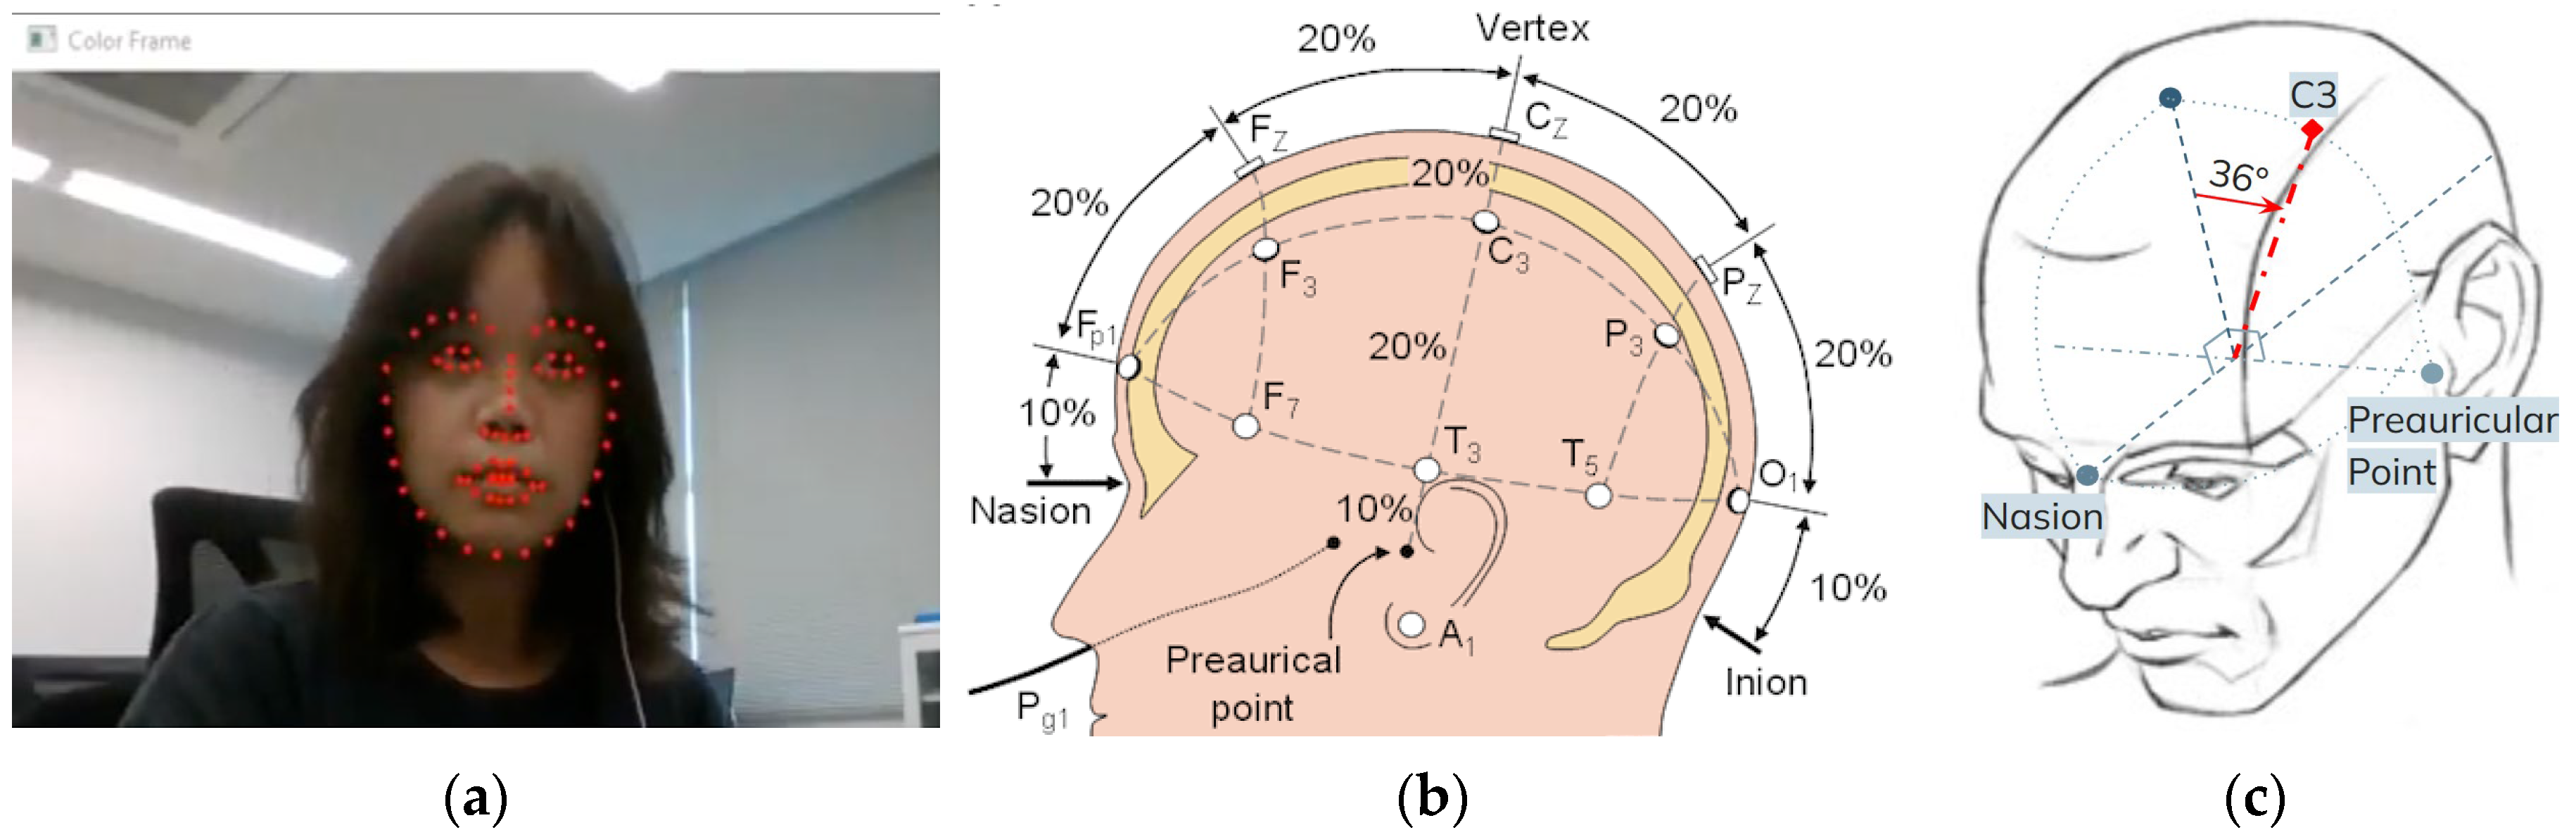
2.3.1. C3 Estimation Procedure
- Define the transverse plane.The distance between the left and right preauricular points is treated as 100% of the transverse arc (180° in the simplified angular model).
- Approximate the vertex.Normally at 50% of the nasion–inion distance; here, it is estimated from the geometric midpoint of the preauricular points and the nasion, which also provides pitch/roll estimation.
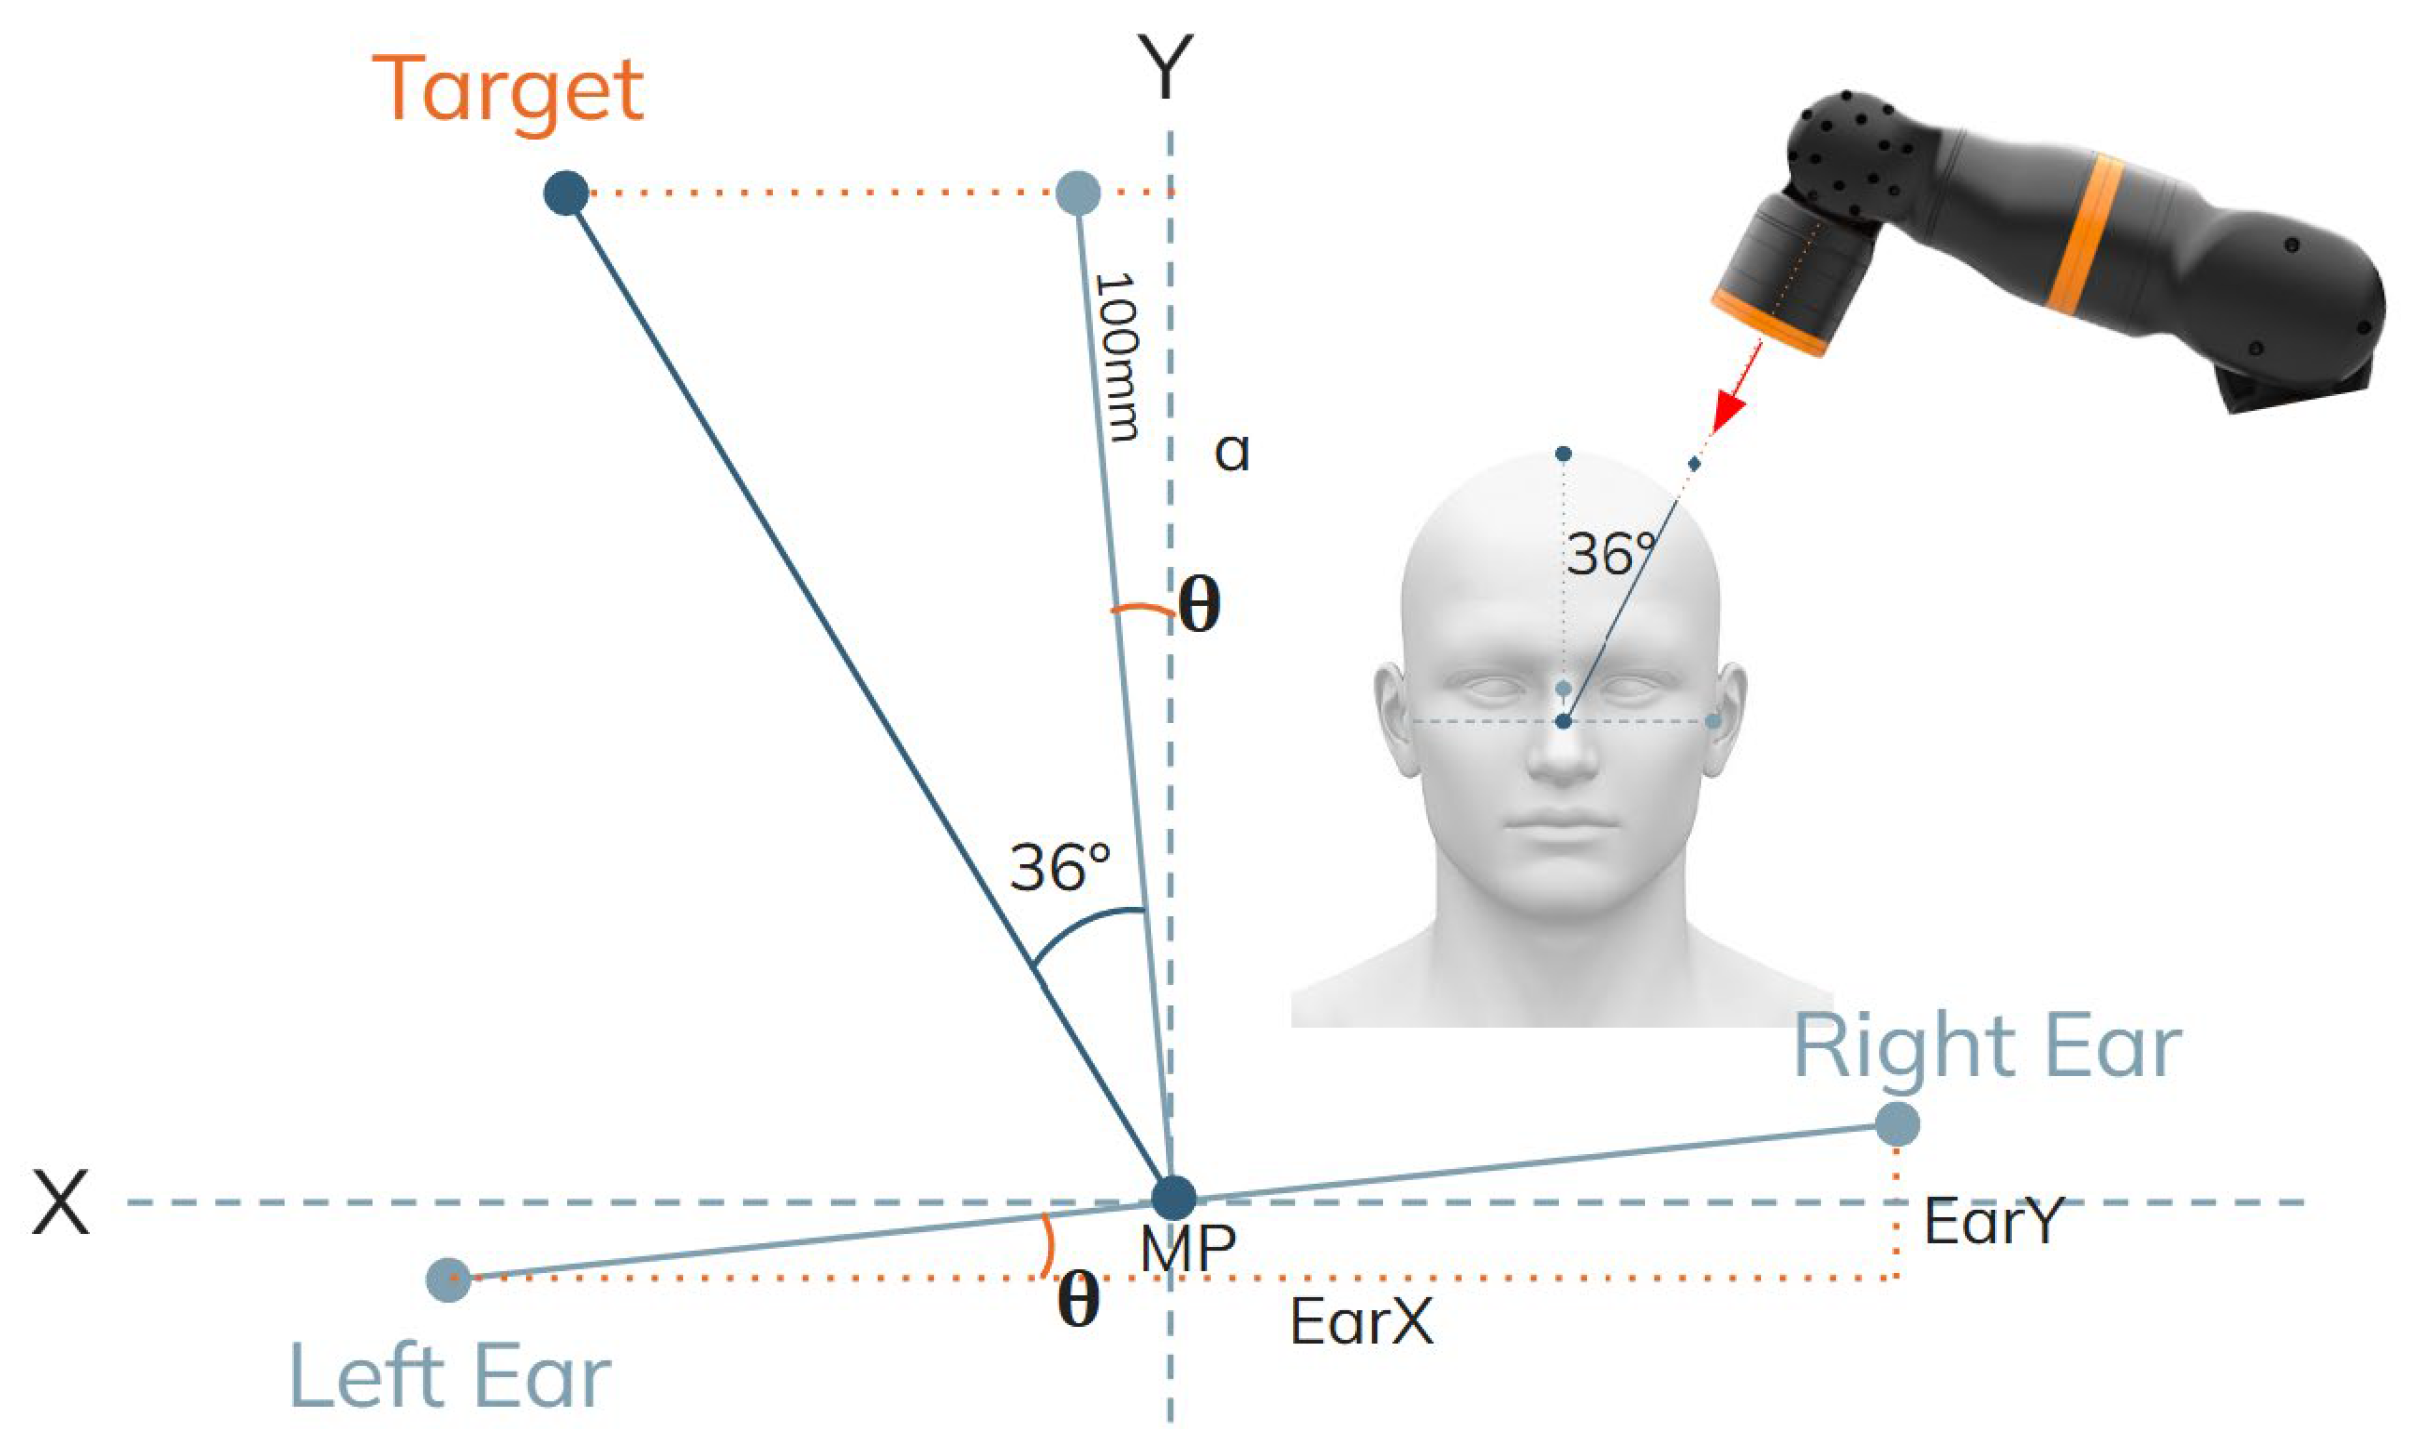
- Locate C3.In the 10–20 system, C3 lies 20% of the transverse distance from the vertex. In the simplified model, 20% of 180° is 36°. The C3 direction is therefore the 36° angle from the vertex toward the left ear.
- Estimate head orientation.Using the nasion–ear triangle, pitch and roll are computed, enabling the C3 point to be projected onto a tilt-corrected anatomical plane.
2.3.2. Coordinate Computation
2.4. Experimental Procedures
2.4.1. MEP Threshold Determination
2.4.2. C3 Localization Experiment
2.4.3. Tilt Verification Experiment
- One suprathreshold TMS pulse was delivered;
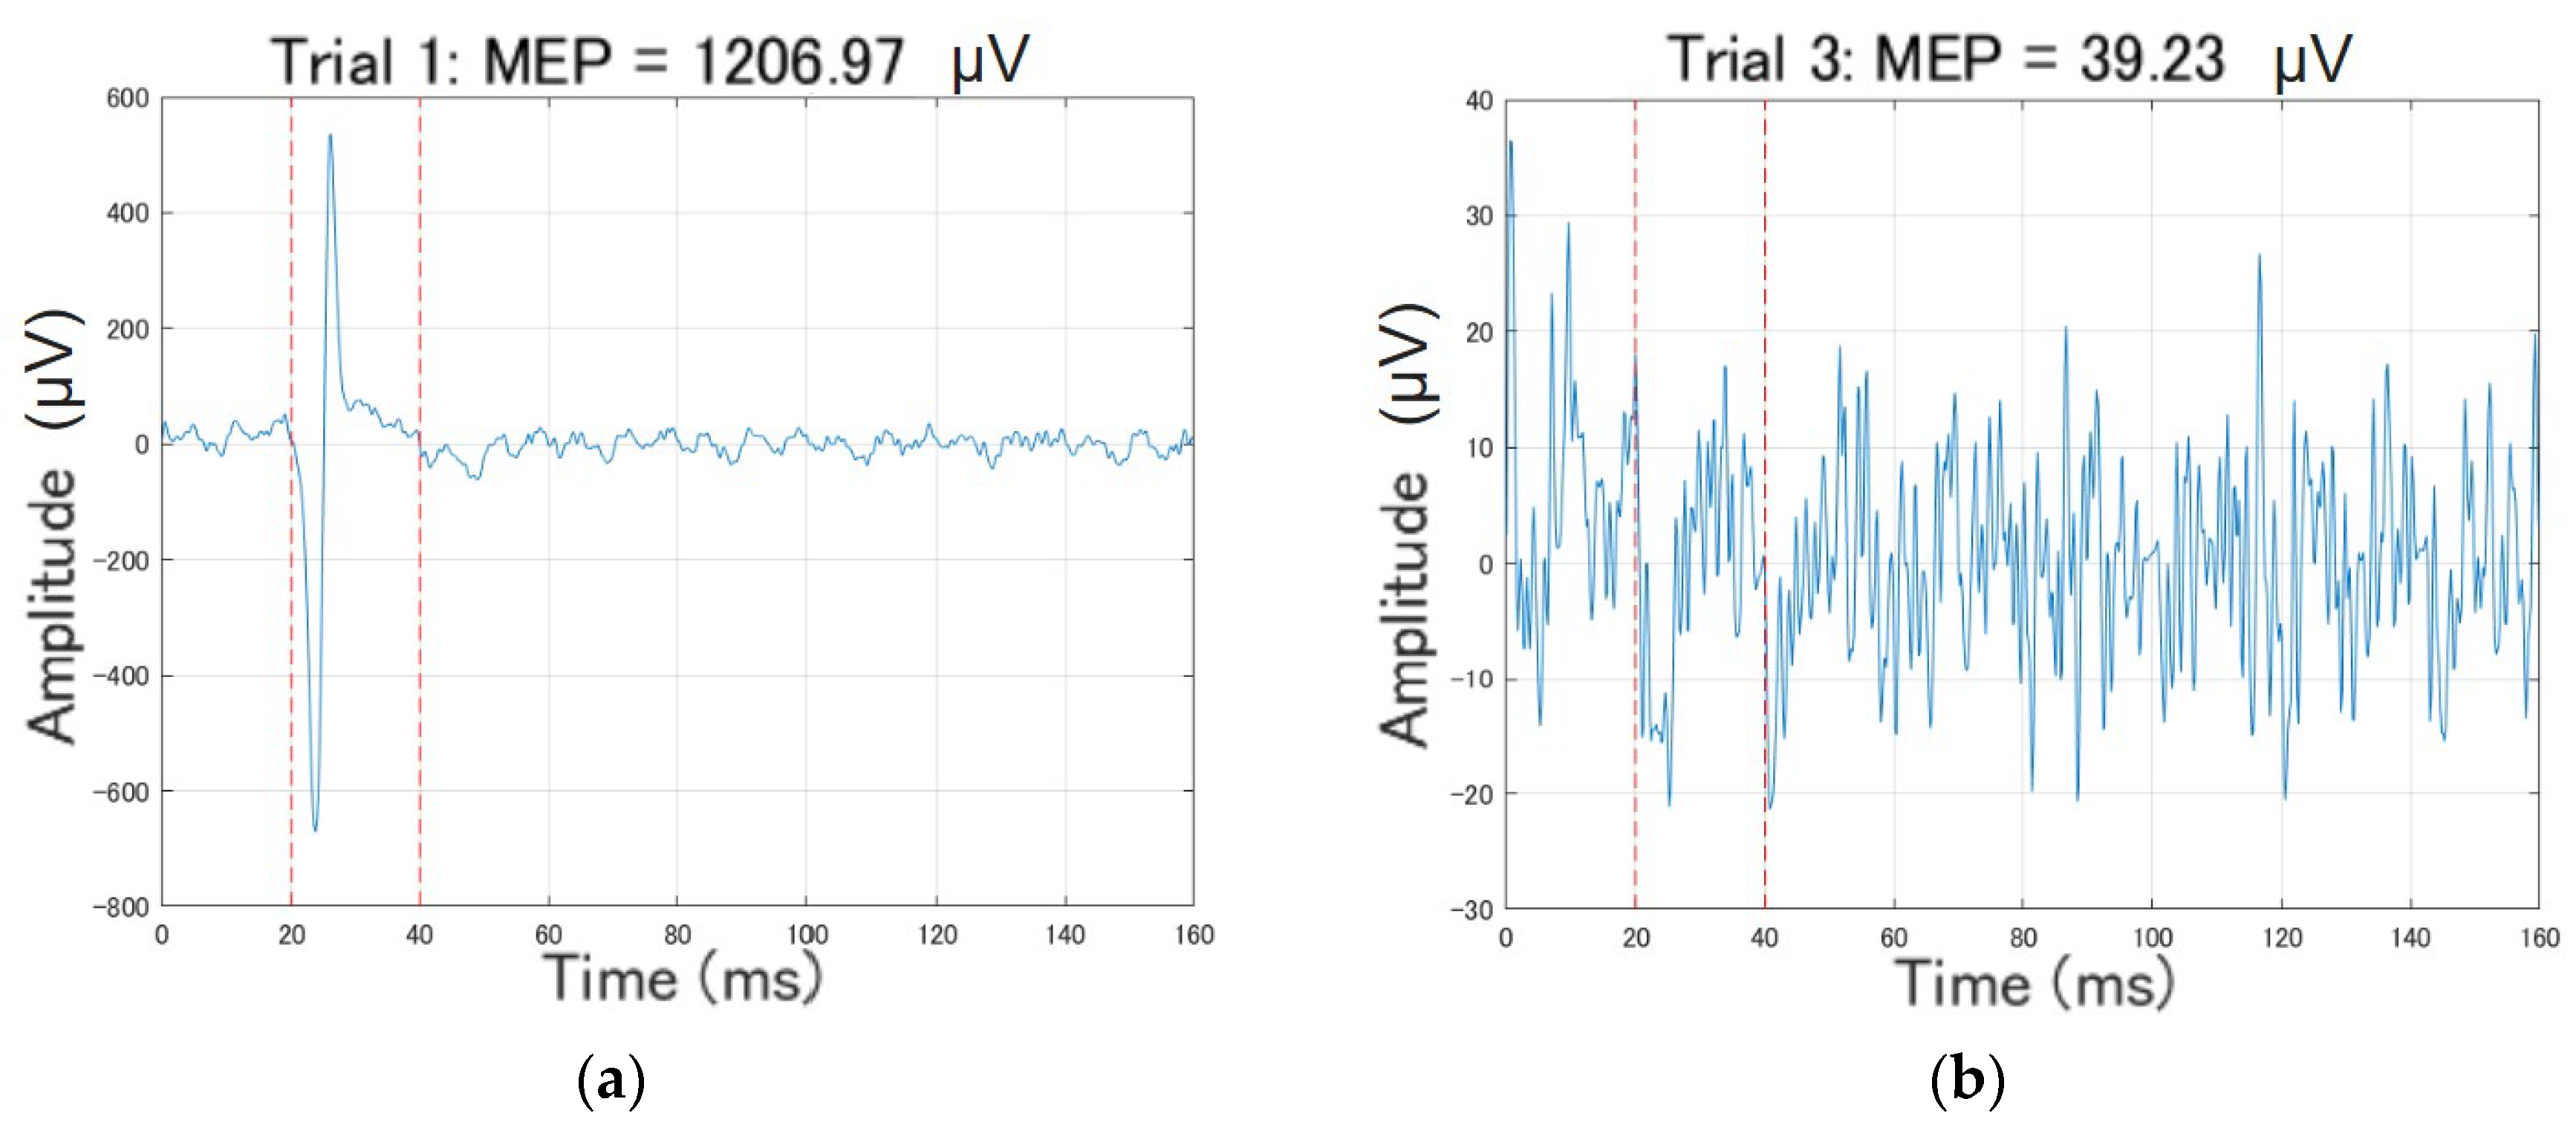
- MEP amplitude and graph were recorded;
- Upper and lower textile sensor total load and normalized readings were logged.
3. Results
3.1. Motor Thresholds of Participants
3.2. C3 Localization
3.3. Tilt Ratio Verification
4. Discussion
4.1. C3 Localization Reliability
4.2. Tilt Verification Implications
4.2.1. Relationship Between Coil Tilt Angle and MEP Amplitude
4.2.2. Sensor Ratio Correlation with MEP Amplitude
4.2.3. Inter-Subject Variability
4.3. Limitations in Sensor Consistency
4.4. Additional Findings
4.5. Future System Improvements
5. Conclusions
Author Contributions
Funding
Institutional Review Board Statement
Informed Consent Statement
Data Availability Statement
Acknowledgments
Conflicts of Interest
Abbreviations
| TMS | Transcranial Magnetic Stimulation |
| MDD | Major Depressive Disorder |
| PDD | Postpartum Depression |
| SUD | Substance Use Disorder |
| MRI | Magnetic Resonance Imaging |
| fMRI | Functional Magnetic Resonance Imaging |
| DOF | Degrees of Freedom |
| iRC | Igus Robot Control |
| CRI | Container Runtime Interface |
| MEP | Motor Evoked Potential |
| FDI | First Dorsal Interosseous |
| RMT | Resting Motor Threshold |
| MSO | Maximum Stimulator Output |
Appendix A


References
- Varone, G.; Biabani, M.; Tremblay, S.; Brown, J.C.; Kallioniemi, E.; Rogasch, N.C. The golden age of online readout: EEG-informed TMS from manual probing to closed-loop neuromodulation. Neuroimage 2025, 322, 121543. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Huddle, M.M.; Costello, S.C.; Barton, D.A. A Systematic Review of the Efficacy of Repetitive Transcranial Magnetic Stimulation Treatment for Women with Postpartum Depression. Psychiatry Int. 2021, 2, 265–276. [Google Scholar] [CrossRef] [Scilit]
- Steele, V.R. Transcranial Magnetic Stimulation as an Interventional Tool for Addiction. Front. Neurosci. 2020, 14, 592343. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Gellersen, H.M.; Kedzior, K.K. Antidepressant outcomes of high-frequency repetitive transcranial magnetic stimulation (rTMS) with F8-coil and deep transcranial magnetic stimulation (DTMS) with H1-coil in major depression: A systematic review and meta-analysis. BMC Psychiatry 2019, 19, 139. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- MacMaster, F.P.; Croarkin, P.E.; Wilkes, T.C.; McLellan, Q.; Langevin, L.M.; Jaworska, N.; Swansburg, R.M.; Jasaui, Y.; Zewdie, E.; Ciechanski, P.; et al. Repetitive Transcranial Magnetic Stimulation in Youth with Treatment Resistant Major Depression. Front. Psychiatry 2019, 10, 170. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Sondergaard, R.E.; Martino, D.; Kiss, Z.H.T.; Condliffe, E.G. TMS Motor Mapping Methodology and Reliability: A Structured Review. Front. Neurosci. 2021, 15, 709368. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Kingsly, E.N.; Bozkurt, I.; Chaurasia, B. Neuro-navigation: Equipment, Tips, and Tricks on Brain Navigated Surgery. Indian J. Neurosurg. 2023, 12, 193–202. [Google Scholar] [CrossRef] [Scilit]
- Jaroonsorn, P.; Neranon, P.; Smithmaitrie, P.; Dechwayukul, C. Robot-Assisted Transcranial Magnetic Stimulation Using Hybrid Position/Force Control. Adv. Robot. 2020, 34, 1559–1570. [Google Scholar] [CrossRef] [Scilit]
- Shin, H.; Ryu, W.; Cho, S.; Yang, W.; Lee, S. Development of a Spherical Positioning Robot and Neuro-Navigation System for Precise and Repetitive Non-Invasive Brain Stimulation. Appl. Sci. 2019, 9, 4561. [Google Scholar] [CrossRef] [Scilit]
- igus GmbH. ReBeL Cobot 5 DOF; igus: Cologne, Germany, 2025. Technical Data. Available online: https://www.igus.eu/product/22534?artNr=REBEL-5DOF-03 (accessed on 23 November 2025).
- igus GmbH. Safety Instructions for ReBeL Cobots; igus: Cologne, Germany, 2024. EC Machinery Directive, Safe Spatial Borders. Available online: https://www.igus.eu (accessed on 23 November 2025).
- ISO/TS 15066:2016; Robots and Robotic Devices—Collaborative Robots, 1st ed. International Organization for Standardization (ISO): Geneva, Switzerland, 2016; Last Reviewed and Confirmed 2022. Available online: https://www.iso.org/standard/62996.html (accessed on 23 November 2025).
- RealSense, Inc. Stereo Depth Camera D435; Product Page; RealSense: Santa Clara, CA, USA, 2025; Available online: https://www.realsenseai.com/products/stereo-depth-camera-d435/ (accessed on 12 January 2026).
- Takeuchi, T. DlibDotNet: Dlib .NET Wrapper Written in C++ and C#; GitHub Repository, 2025. Available online: https://github.com/takuya-takeuchi/DlibDotNet (accessed on 23 November 2025).
- Artinis Medical Systems. What Is the 10–20 System for EEG? TMSi—An Artinis Company Blog. 24 January 2024. Available online: https://www.tmsi.artinis.com/blog/the-10-20-system-for-eeg (accessed on 23 November 2025).
- Magstim Co., Ltd. MagStim 200; Magstim: Whitland, UK, 2025; Available online: https://www.magstim.com/product/magstim-m200%C2%B2/ (accessed on 26 November 2025).
- Janssen, A.M.; Oostendorp, T.F.; Stegeman, D.F. The coil orientation dependency of the electric field induced by TMS for M1 and other brain areas. J. Neuroeng. Rehabil. 2015, 12, 47. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Adank, P.; Kennedy-Higgins, D.; Maegherman, G.; Hannah, R.; Nuttall, H.E. Effects of coil orientation on motor evoked potentials from Orbicularis Oris. Front. Neurosci. 2018, 12, 683. [Google Scholar] [CrossRef] [Scilit] [PubMed]



| Subject | Dominant Hand | RMT (%) | 120% RMT (%) |
|---|---|---|---|
| A | Right | 62 | 74 |
| B | Right | 50 | 60 |
| C | Right | 55 | 66 |
| D | Right | 45 | 54 |
| E | Right | 64 | 77 |
| Subject | Trial | Attempts | Remarks |
|---|---|---|---|
| A | 1 | 5 | Attempts 1–4: coil not positioned at 45 degrees |
| 2 | 1 | Successful | |
| 3 | 1 | Successful | |
| B | 1 | 3 | Recalibrated for height difference |
| 2 | 1 | Successful | |
| 3 | 1 | Successful | |
| C | 1 | 4 | Physically moved the cobot slightly backward |
| 2 | 2 | Recalibrated target a bit closer to vertex | |
| 3 | 1 | Successful | |
| D | 1 | 2 | Reverted to original target calibration |
| 2 | 1 | Successful | |
| 3 | 1 | Successful | |
| E | 1 | 1 | Successful |
| 2 | 1 | Successful | |
| 3 | 1 | Successful |
| Trial | Robot Pitch Angle | Total Load | Norm Ch0 | Norm Ch1 | MEP (µV) |
|---|---|---|---|---|---|
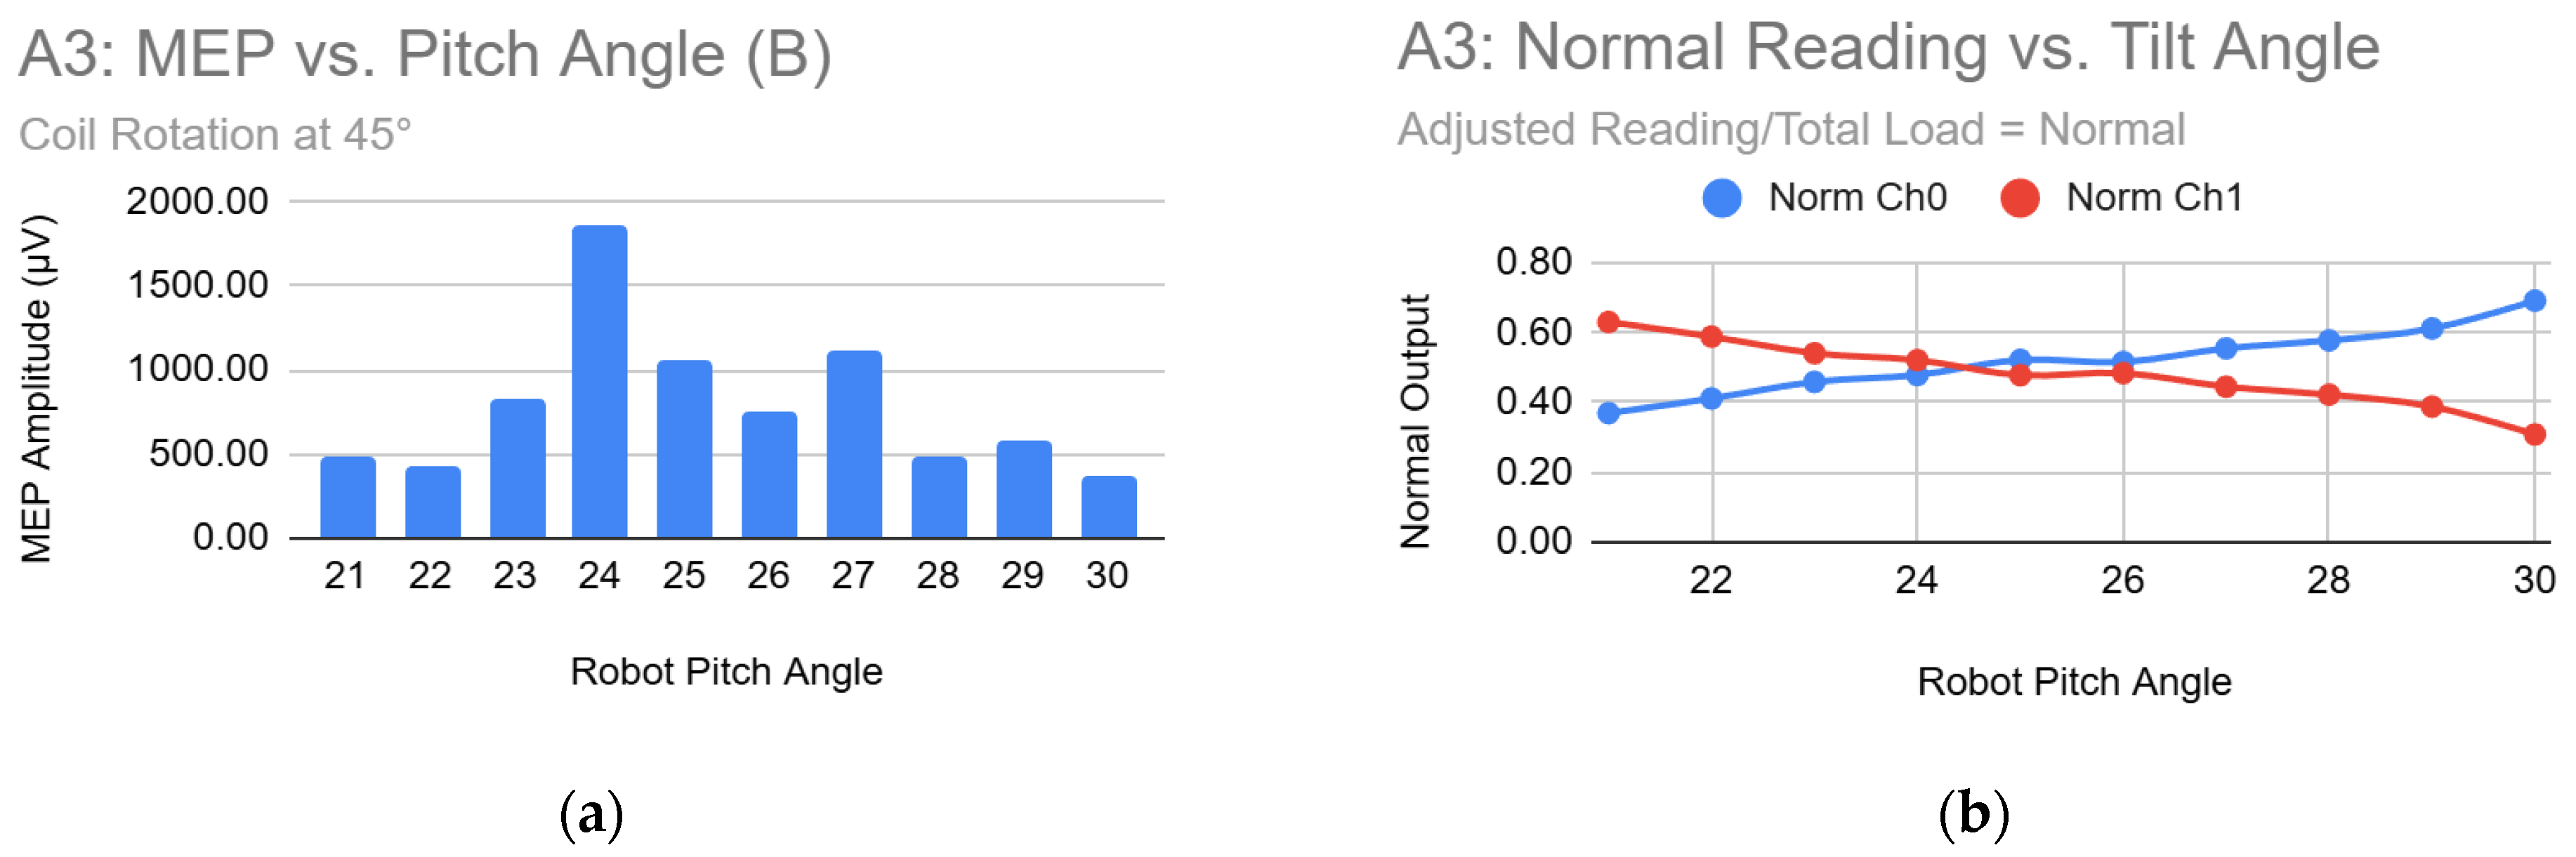
| Trial 3 | 21 | 1867 | 0.37 | 0.63 | 492.47 |
| 22 | 1777 | 0.41 | 0.59 | 434.43 | |
| 23 | 1863 | 0.46 | 0.54 | 834.70 | |
| 24 | 1769 | 0.48 | 0.52 | 1861.40 | |
| 25 | 1669 | 0.52 | 0.48 | 1067.20 | |
| 26 | 1731 | 0.52 | 0.48 | 748.72 | |
| 27 | 1795 | 0.55 | 0.45 | 1108.10 | |
| 28 | 1752 | 0.58 | 0.42 | 483.87 | |
| 29 | 1741 | 0.61 | 0.39 | 572.38 | |
| 30 | 1614 | 0.69 | 0.31 | 367.76 |
Disclaimer/Publisher’s Note: The statements, opinions and data contained in all publications are solely those of the individual author(s) and contributor(s) and not of MDPI and/or the editor(s). MDPI and/or the editor(s) disclaim responsibility for any injury to people or property resulting from any ideas, methods, instructions or products referred to in the content. |
© 2026 by the authors. Licensee MDPI, Basel, Switzerland. This article is an open access article distributed under the terms and conditions of the Creative Commons Attribution (CC BY) license.
Share and Cite
Ompico, C.D.S.; Banayo, J.N.; Mashio, Y.; Odagaki, M.; Kikuchi, Y.; Sy, A.C.; Kurosaki, H. Development of a Robot-Assisted TMS Localization System Using Dual Capacitive Sensors for Coil Tilt Detection. Sensors 2026, 26, 693. https://doi.org/10.3390/s26020693
Ompico CDS, Banayo JN, Mashio Y, Odagaki M, Kikuchi Y, Sy AC, Kurosaki H. Development of a Robot-Assisted TMS Localization System Using Dual Capacitive Sensors for Coil Tilt Detection. Sensors. 2026; 26(2):693. https://doi.org/10.3390/s26020693
Chicago/Turabian StyleOmpico, Czaryn Diane Salazar, Julius Noel Banayo, Yamato Mashio, Masato Odagaki, Yutaka Kikuchi, Armyn Chang Sy, and Hirofumi Kurosaki. 2026. "Development of a Robot-Assisted TMS Localization System Using Dual Capacitive Sensors for Coil Tilt Detection" Sensors 26, no. 2: 693. https://doi.org/10.3390/s26020693
APA StyleOmpico, C. D. S., Banayo, J. N., Mashio, Y., Odagaki, M., Kikuchi, Y., Sy, A. C., & Kurosaki, H. (2026). Development of a Robot-Assisted TMS Localization System Using Dual Capacitive Sensors for Coil Tilt Detection. Sensors, 26(2), 693. https://doi.org/10.3390/s26020693