


Abstract
A graph-theoretical approach to the analysis of motion and rest in many-body systems is developed. Point bodies are represented as vertices of a complete bi-colored graph, termed the motion–rest graph (MRG). Two vertices are connected by a rust-colored edge when the corresponding bodies are at rest relative to each other; that is, when their mutual distance remains constant in time, bodies moving relative to each other are connected by a cyan edge. It is shown that the logical structure of the relation “to be at rest relative to each other” determines the combinatorial structure of the graph. For one-dimensional motion in classical mechanics and special relativity, this relation is reflexive, symmetric, and transitive, and therefore defines an equivalence relation. As a result, rust edges form disjoint complete cliques corresponding to rest-clusters, and the MRG becomes a semi-transitive complete bi-colored graph that is completely determined by the partition of the bodies into equivalence classes. It is proven that any such graph on five vertices necessarily contains a monochromatic triangle. For two- and three-dimensional motion, the transitivity of relative rest generally fails because constant mutual distance does not imply an equality of velocities in the presence of rotational degrees of freedom. In this case, the MRG is non-transitive, and the Ramsey threshold becomes the classical value R(3, 3) = 6. The approach is extended to mixed sets containing moving bodies and reference points, including the center of mass of the system. Generalizations to general relativity and quantum mechanics are also discussed. In general relativity, transitivity of relative rest is generically lost because global rigid congruences do not generally exist. In quantum mechanics, exact transitivity survives only at the level of idealized delocalized eigenstates, whereas for physically realizable localized states, the notion of mutual rest becomes only approximate. The results demonstrate that the interplay between kinematics, logical properties of relational motion, and Ramsey-type combinatorial constraints gives rise to unavoidable ordered substructures in many-body systems.
Keywords:
motion; logic; transitivity; semi-transitive graphs; Ramsey theory; relativity; quantum mechanics 1. Introduction
The introduction of new mathematical methods in physics in recent decades has been extremely fruitful. Topology turned out to be effective in physics because many physical laws depend on global structure and robust invariants rather than microscopic details [1,2,3]. Category theory also opens new horizons in physics [4]. Category theory replaces the question “What is the physical object?” with the questions “What can be done with it?” and “How do processes compose?” which are natural in physics [4]. Perhaps the most fruitful development has been the application of graph-theoretical methods in physics [5,6,7,8]. A graph is an ordered pair where V is a finite or countable set whose elements are called vertices (or nodes), and E is a set of edges (or links), where each edge is a relation between vertices [9,10]. Uncertainty relations valid for any set of dichotomic observables arising from the graph theory were reported [5].
The present paper is devoted to the application of colored, complete graphs, also known as Ramsey graphs, to the fundamental problems of dynamics, namely, to distinguishing between subsets of bodies that move relative to each other and subsets of bodies that are at rest relative to each other. A colored graph is an ordered triple where V is a finite set of vertices, E is a set of edges, and c is a coloring function assigning to each edge a color from a set C of colors. A complete graph is a graph in which every pair of distinct vertices is connected by an edge. A complete colored graph is a complete graph whose edges are colored by a finite set of colors [11,12,13,14]. Ramsey theory guarantees that for sufficiently many vertices, any such coloring necessarily contains a monochromatic complete subgraph of prescribed size [11,12,13,14]. The Ramsey number is the smallest integer N, such that any complete graph on N vertices whose edges are colored with two colors contains either a monochromatic of the first color or a monochromatic of the second color. Thus, any sufficiently large system of N interacting objects must contain an unavoidable ordered substructure, regardless of how the pairwise relations are assigned. Consider N objects (vertices), where every pair interacts, and each interaction is classified into one of two types (e.g., compatible/incompatible, allowed/forbidden, same phase/opposite phase). Then, is the minimal N, such that for any assignment of interaction types, the system necessarily contains either a subset of k objects whose all mutual interactions are of type A, or a subset of l objects whose all mutual interactions are of type B [10,11,12,13,14]. We demonstrated the Ramsey approach for the analysis of the kinematics of non-relativistic material points [15]. Point masses served as the vertices of the graph. The time dependence of the distance between the particles determined the coloring of the edges [15]. The particles were connected by links A when particles moved away from each other or remained at the same distance. The particles were linked with links B when they converged [15]. The sign of the time derivative of the distance between the point masses established the color of the link [15]. At least one monochromatic triangle inevitably appears in the graph, emerging from the motion of six particles due to the fact that the aforementioned Ramsey number R(3, 3) = 6. Now, we extend the introduced approach for the Ramsey analysis of the points that are at rest/move relative to each other. We demonstrate that the combination of the logic of the space–time relations with combinatorial restrictions dictates the coloring of the graph.
This paper is built as follows: (i) motion–rest graphs are introduced; (ii) semi-transitive motion graphs emerging for 1D motion of material points are treated; (iii) non-transitive graphs inherent for 2D and 3D classical motion of material points are addressed; (iv) graphs representing moving bodies and reference points are discussed; (v) general relativity aspects of the motion–rest graphs are addressed; (vi) motion–rest graphs that are inherent for quantum particles are discussed.
The mathematically rigorous core of this paper is the graph-theoretical analysis of motion–rest graphs: for one-dimensional motion, the transitivity of relative rest and the resulting structural theorems are proved, while for generic two- and three-dimensional non-transitive motion, the existence of monochromatic triangles follows rigorously from the classical Ramsey result . The molecular interpretation and the discussions of general relativity and quantum mechanics should be understood as physically motivated extensions and heuristic indications of broader applicability.
2. Results
2.1. Introducing the Coloring Procedure and Formation of the Motion–Rest Graph
Consider two point bodies and . We represent the bodies by two vertices of a graph, as shown schematically in Figure 1. There exist two possibilities: (i) The bodies are at rest relative to each other. In this situation, the bodies are connected by the rust-colored edge (see Figure 1A). Or, (ii), the bodies move relative to each other. In this case, the bodies are connected by the cyan-colored edge (see Figure 1B). These possibilities are mutually exclusive.
Figure 1.
Coloring procedure is depicted. (A) Bodies and represented by two vertices are at rest relative to each other. The bodies/vertices are connected by the rust-colored edge. (B) Bodies and move relative to each other. They are connected by the cyan edge.
Let us define precisely the relation “to be at rest relative to each other” for two particles. The particles numbered “1” and “2” are at rest relative to each other when Equation (1) holds:
where is the distance between the particles. If the distance is time-dependent, that is:
then, the bodies move relative to each other. It is important to emphasize that the condition does not, in general, imply , where and are the instantaneous velocities of the particles. The simplest example, illustrating this, is shown in Figure 2, depicting the uniform motion of the point particles and around the circle. This is true in the case of 2D and 3D motions. In the case of 1D motion, does necessarily imply .
Figure 2.
The point particles and perform uniform motion around the circle., and the particles are at rest relative to each other; the velocities of the particles are not equal.
Let us define the 1D motion-rest graph rigorously.
Definition 1.
Let be point bodies moving on a line, with positions The motion–rest graph (MRG) , where and the coloring c is defined by .
Equivalently (for differentiable motion), .
Now, we discuss the logic properties of the introduced coloring.
- (i)
- The relation “to be at rest” is logically reflexive. Every body is at rest relative to itself. The relation “to be at rest” is also logically symmetric. If point body “1” is at rest relative to body “2”, body “2” is at rest relative to body “1”. The relation “to be at rest relative to each other” may be transitive and non-transitive in classical mechanics and special relativity (the general relativity and quantum mechanics generalizations will be discussed below). Let us discuss the transitivity of rest in detail. Consider the one-dimensional (1D) motion of three point bodies , and . The velocities of the bodies may be parallel or anti-parallel to each other. If the body is at rest relative to , and the body is at rest relative to , necessarily the body is at rest relative to i.e., if , necessarily in the case of 1D motion. Moreover, if in some inertial frame we have and , it necessarily implies This fact is extremely important from the graph-theoretical point of view. Thus, the relation of being connected by a rust edge is transitive for 1D motion. Moreover, this property does not depend on the choice of frames because equality of velocities is preserved under Galilean or Lorentz transformations, as it will be rigorously demonstrated below. This is not true for 2D and 3D motion of three bodies, as it will be discussed below in detail. Thus, we come to a very important conclusion: the property “to be at rest relative to each other” may be transitive and non-transitive in classical mechanics and special relativity, depending on the dimensionality of the motion: it is transitive for 1D motion, and it is generally non-transitive for 2D and 3D motion of the bodies. This will be illustrated below with examples.
- (ii)
- The property “to move relative to each other” is not reflexive. A body does not move relative to itself. The property “to move relative to each other” is symmetrical. If point body “1” is moving relative to body “2”, body “2” is moving relative to body “1”. The property “to move relative to each other” is not transitive for 1D, 2D, and 3D motion of point bodies. Consider three bodies , and . If the body moves relative to , and the body moves to , it is possible that the body is at rest relative to , and it is also possible that the body moves relative to . Thus, the property “to be connected” by a cyan edge is not transitive, regardless of the dimensionality of the motion, and the non-transitivity holds in general relativity and quantum mechanics.
- (iii)
- The introduced coloring scheme is frame-independent in the realms of both classic and relativistic mechanics.
- (iv)
- The definition of relative rest adopted here, based on the constancy of pairwise distance, is strictly weaker than the condition of equality of velocities. Indeed, equality of velocities implies constancy of the distance, but the converse is not generally true. The adopted definition is essential, as it naturally includes rigid motions such as rotations. In one-dimensional motion, the two definitions coincide, whereas in higher dimensions, they differ. It is precisely this difference that leads to the failure of transitivity of relative rest in dimensions greater than one.
2.2. Analysis of 1D Motion of Three Bodies
We denote the aforementioned graphs as motion–rest graphs, and abbreviate them to MRG. Let us start from the MRG emerging in classical mechanics and special relativity for the 1D motion of three bodies, illustrated with Figure 3.
Figure 3.
Three point bodies , and moving along axis If , necessarily . If in some inertial frame we have and , necessarily Point bodies and are at rest relative to each other. The property “to be at rest relative to each other” is transitive for 1D motion. If and , body is at rest relative to , i.e., , and bodies and are moving relative to , If all three bodies are moving relative to each other. The property “to be at rest relative to each other” may be transitive and non-transitive.
The MRG depicted in Figure 4 illustrates the transitivity of the property “to be at rest relative to each other”, and non-transitivity of the property “to move relative to each other” in classical mechanics and special relativity in the particular case of 1D motion. The graph depicted in Figure 4A corresponds to the situation when the triad of point masses is at rest relative to each other. However, it is possible that the bodies are motile in the laboratory frame of reference. This is the case when depicted in Figure 3. The graph presented in Figure 4A also corresponds to the acoustic branch of 1D oscillations in a periodic system of masses, whose unit cell consists of three masses oscillating in phase.
Figure 4.
Motion–rest graphs (MRG) for three-body problems in classical mechanics and special relativity for 1D motion. (A) Three bodies are at rest relative to each other. The graph illustrates the transitivity of the property “to be at rest one relative to other”. (B) Body moves relatively to bodies and . Bodies and are at rest relative to each other. The property “to be connected by the cyan edge” is not transitive. (C) The triad of bodies and move relatively to each other; rust color depicts relative rest; cyan color depicts relative motion.
The 1D nature of the motion of three bodies is not conserved in all of the inertial frames. A motion that is one-dimensional in one inertial frame may appear two-dimensional in another inertial frame. Consider the 1D motion of three bodies depicted in Figure 3, as it is seen by the observer moving with a constant speed normal to and . Assume The relative motion of the bodies is seen by the observer as 2D motion. However, the coloring of the MRG graph remains untouched; indeed, or alternatively, remain the same in any of the frames.
Now, let us rigorously prove that the property “to be at rest” holds for the 1D motion in special relativity in any inertial frame. First of all, it is necessary to define exactly what the 1D motion is in special relativity. In special relativity, the minimal number of dimensions of the motion is two, namely, the pair . Therefore, when we speak about 1D relativistic motion, we mean the motion in which the entire set of bodies moves along axis X. Now, we have to define the relativistic property “to be at rest relative to each other”. Suppose that in some inertial frame S, two particles satisfy . In this case, we say that the particles are at rest, each relatively to the other. For inertial one-dimensional motion, this implies equality of their velocities . Under a Lorentz transformation to another inertial frame moving with velocity u along the same axis, the coordinate difference transforms as
Therefore, in frame Hence, the particles again have equal velocity vectors in , and their mutual distance remains constant in time. We demonstrated it for the situation when velocity u is aligned along axis X. The generalization for the arbitrary direction of is straightforward. By definition, two particles are at rest relative to each other in an inertial frame S if the distance between them is constant in time: Assume now that both particles move inertially. Then, their trajectories in S may be written as:
Hence:
If the distance for all t, then necessarily Now, consider another inertial frame , moving with an arbitrary constant velocity relative to S. Since , the relativistic velocity transformation sends these equal velocities into equal transformed velocities: . Therefore, in frame the separation vector again has the form:
Hence, since . It follows:
Therefore, if two inertially moving particles are at rest relative to each other in one inertial frame, then they are at rest relative to each other in every inertial frame for an arbitrary direction of the boost velocity . Thus, if two particles are at rest relative to each other in one inertial frame, they are at rest relative to each other in every inertial frame. In relativistic terms, this corresponds to the constancy of the space-like interval between equal-time events on the two worldlines. Therefore, in special relativity, the relation “to be at rest relative to each other” is reflexive, symmetric, and transitive in the case of 1D inertial motion. We conclude that the rust edge of the MRG graph is Lorentz-invariant in the case of the 1D motion. And again, within the inertial frame , moving with an arbitrary constant velocity (which is not aligned along axis X) relative to S, the motion is seen as 2D motion.
Within the present graph-theoretic definition, the relation “to be at rest relative to each other” is also reflexive, symmetric, and transitive for photons propagating along the same line. A similar conclusion applies to photons moving along the same line: if two photons propagate in the same direction and maintain constant separation, then within the present graph-theoretic definition, they are regarded as being “at rest relative to each other”. This statement is specific to 1D propagation and does not generally hold for 2D or 3D motion.
The relation “to be at rest relative to each other” may be transitive in the particular cases of 2D and 3D motions. The fixed triangular configuration is preserved throughout any classical motion of the rigid body (whether translational or rotational). This is also the situation of the famous Lagrange triangle [16,17,18,19]. The Lagrange solution of the 3D classical three-body problem corresponds to a special symmetric configuration that was first identified by Joseph-Louis Lagrange in 1772. In this solution, three bodies with masses occupy the vertices of an equilateral triangle [16,17,18,19]. The mutual separations between the points constituting the body remain equal and constant: . Depending on the initial conditions, the bodies move along circular or elliptical orbits while maintaining this fixed geometric arrangement, corresponding to the MRG graph, shown in Figure 4A. It should be emphasized that the Lagrange triangle is a very specific case of 3D motion; generally, the relation “to be at rest” is not transitive for 2D and 3D motions, as it will be discussed below in detail.
The introduced coloring procedure leads to the important mathematical conclusion: rust edges form equivalence classes and induce a partition of the system. Recall that an equivalence class is a subset of a larger set that groups elements together based on a specific equivalence relation (a relationship that is reflexive, symmetric, and transitive). The relation “to be at rest relatively to each other” is reflexive, symmetric, and transitive for the 1D motion. Thus, a subset of bodies that are at rest relatively to each other forms the equivalence class. Physically, each equivalence class corresponds to a cluster of bodies whose mutual distances remain constant in time. In the particular case of one-dimensional inertial motion, this condition is equivalent to equality of their velocities. Implications of this conclusion will be discussed below. It is extremely important that the coloring of classical motion–rest graphs does not depend on the frame of reference. Only the relative motion of the point masses is important.
Now consider the graph emerging for the 1D motion of four classical point masses, shown in Figure 5.
Figure 5.
Motion–rest complete bi-colored graph emerging for the 1D motion of four classical point masses. The graph contains no monochromatic triangle. Rust color depicts relative rest; cyan color depicts relative motion.
From the physical point of view, the MRG depicted in Figure 5 represents the 1D motion of two rigid dumbbells, namely and aligned along the same axis, represented by the rest edges. The graph shown in Figure 5 contains no monochromatic triangle. This means that there is no triad of bodies that are at rest relative to each other. It is noteworthy that introducing any additional rust edge into the graph depicted in Figure 5 converts it into a complete rust graph.
Now, consider the MRG graph emerging for the 1D motion of five point classical masses, shown in Figure 6.
Figure 6.
Motion–rest complete bi-colored graph emerging for the 1D motion of five classical point masses. Triangles and are monochromatic cyan. Rust color depicts relative rest; cyan color depicts relative motion.
We demonstrated that any semi-transitive bi-colored complete graph containing five vertices inevitably contains at least one monochromatic triangle [20]. Indeed, triangles and appearing in Figure 6, are monochromatic cyan. Let us supply a physical interpretation to this result. Bodies and are at rest relative to each other; bodies and are also at rest relative to each other; body moves relative to all four bodies. We may consider this motion as the 1D motion of body relatively to two rigid dumbbells, namely and represented by the rust edges. Relative motion between the two pairs/dumbbells is arbitrary but nonzero. From the graph-theoretical point of view, any triangle containing and one vertex from each rigid pair is necessarily monochromatic cyan. This example demonstrates that even minimal transitivity (only two rust edges) is enough to enforce Ramsey-type constraints once five vertices are present.
Consider one more example. Assume that bodies form a rigid 1D cluster: all mutual distances between these three bodies are constant in time. Thus, the edges and aligned along axis X are colored rust. Let bodies and move independently with respect to this cluster and with respect to each other along axis x. Then, all edges connecting or to any of , as well as the edge , are colored cyan. The three vertices necessarily form a monochromatic cyan triangle. No choice of inertial frame removes this triangle since the coloring depends only on relative motion. This example illustrates how the coexistence of one equivalence class (rust edges) with moving bodies inevitably generates a cyan clique.
These examples show that for the 1D motion of five classical point bodies, the coexistence of a transitive relation (“relative rest”) with a non-transitive one (“relative motion”) imposes strong combinatorial constraints. As soon as the system exceeds four bodies, monochromatic triangles become unavoidable, even though the coloring is not arbitrary but dictated by physical kinematics. This result is summarized by Theorem 1.
Theorem 1.
Consider the 1D motion of five point bodies . The bodies are represented by the vertices of the graph. The bodies/vertices are connected by the rust-colored edge when the bodies are at rest, each relatively to the other. Bodies that move relative to each other are connected by the cyan edge. Thus, the complete, bi-colored, rest–motion graph emerges. This graph is semi-transitive and contains at least one monochromatic triangle.
The theorem holds in the realm of special relativity. And it holds if the set of objects moving in 1D is a mixture of material points and photons. It also holds for the set of photons.
Theorem 1 may be re-formulated in a more rigorous mathematical way, exploiting the notion of equivalence.
Theorem 2.
For one-dimensional motion, the relation “to be at rest relative to each other” defines an equivalence relation on the set of bodies. Therefore, the corresponding motion–rest graph is a complete bi-colored graph whose rust edges form disjoint complete cliques, while every edge connecting different cliques is cyan. Consequently, the graph is completely determined by the partition of the bodies into equivalence classes of relative rest. In particular, any such graph on five vertices necessarily contains a monochromatic triangle.
Theorem 1 contains one more hidden result.
Theorem 3.
For the 1D motion, the motion–rest graph is exactly the complete multipartite graph determined by equivalence classes of equal velocity.
Equivalence classes play an important role in many areas of physics because they allow one to group objects, states, or configurations that are physically indistinguishable according to a given criterion. A relation is called an equivalence relation if it is reflexive, symmetric, and transitive; such a relation partitions the underlying set into disjoint equivalence classes. In physical theories, these classes often correspond to sets of states that share the same observable properties. For example, in statistical mechanics, many microscopic configurations belong to the same thermodynamic macrostate; in quantum mechanics, state vectors differing only by a global phase represent the same physical state; and in gauge theories, different potentials related by a gauge transformation describe the same physical field configuration. In the present work, for one-dimensional inertial motion, the relation “to be at rest relative to each other” satisfies the properties of an equivalence relation. Consequently, the set of bodies decomposes into equivalence classes of relative rest, i.e., clusters of bodies whose mutual distances remain constant in time. These rest-clusters determine the structure of the motion–rest graph and provide the natural partition underlying its Ramsey-type properties.
It is important that the structure of the semi-transitive MRG emerging for the 1D motion of point bodies is prescribed not only by combinatorial restrictions, but also by the logical structure imposed by the physical nature of the 1D motion. Note the total number of links in the MRG may be presented as:
where and are the number of rust and cyan edges in the graph. If the number of bodies remains constant in the course of the motion, is constant. For the MRG depicted in Figure 6, we calculate and According to the Mantel–Turán limiting theorem, every complete, bi-colored graph with five vertices that contains more than seven monochromatic edges/links inevitably contains at least one monochromatic triangle of the same color. Indeed, cyan triangles appear in the MRG, shown in Figure 6. Thus, the MRG may also illustrate the Mantel–Turán limiting theorem [14,21].
It seems that the transitivity of the rest emerges from the straightness of the 1D trajectory. This is the erroneous conclusion. Actually, it follows from the possibility to describe pairwise separations of the points by one arc-length coordinate, as demonstrated explicitly in Appendix A. Stability of the transitivity is discussed in detail in Appendix B.
2.3. Generalization of the Introduced Graph-Theoretical Approach for the Sets Containing the Mixture of Moving Bodies and Reference Points
The introduced approach may be generalized for the mixed sets containing point bodies performing the 1D motion along axis X, and the reference points located on the same axis X. Consider n point bodies moving along axis X, or alternatively, resting in the laboratory frames, and m reference points moving along axis X, or resting relatively to the same frames. The bodies and points now form the vertices of the MRG graph. The rules of coloring are exactly those that are introduced in Section 2.1. The aforementioned coloring results in the complete, bi-colored graph. The analysis of this graph gives rise to nontrivial results when one of the points is the center of mass of the entire 1D system. Let us illustrate this idea with an example, depicted in Figure 7. We consider the motion of two identical dumbbells relatively to the center of mass of the entire system, depicted with the red point. The numbering of particles is shown in Figure 7: the dumbbells are numbered and , and the center of mass is numbered “3”. Dumbbells move with equal, however, opposite velocities , as shown in Figure 7.
Figure 7.
One-dimensional motion of two identical dumbbells (1, 2) and (4, 5) is depicted. The masses of bodies are identical and equal m. Dumbbells move with equal, however opposite velocities . The center of mass of the system is shown with a red point.
We describe the motion of the dumbbells with the motion–rest graph. However, now we do this with the so-called star-centered representation, shown in Figure 8. A star-centered representation is a graph with one distinguished central vertex connected to all other vertices. It should be emphasized that permutation/relabeling of the bodies/points in the graph depicted in Figure 8 does not change either the number of rust links nor the number of cyan links . This follows from the simple combinatorics reasoning. Thus, the presence of the monochromatic triangles also does not depend on the permutation of the vertices in the graph.
Figure 8.
Motion–rest star-centered graph, corresponding to the motion of the dumbbells, shown in Figure 7. Rep point “3” is the center of masses.
The MRG shown in Figure 8 is a semi-transitive, star-centered graph, containing five vertices. Thus, it inevitably contains at least one monochromatic triangle. Indeed, the triangles (1, 3, 4) and (2, 3, 5) are monochromatic cyan ones. As it was already demonstrated, any semi-transitive graph containing five vertices inevitably contains at least one monochromatic triangle. This leads to the following theorem.
Theorem 4.
Consider the set of four point bodies performing the 1D motion along axis X. We prepare the motion–rest graph, whose vertices are the moving bodies and the center of masses of the system. The vertices are connected by the rust-colored edge when the bodies/centers of the masses are at rest, each relatively to the other. The vertices that move relative to each other are connected by the cyan edge. Thus, the complete, bi-colored, rest–motion graph emerges. This graph is semi-transitive and contains at least one monochromatic triangle, whatever is the motion of the bodies.
2.4. Motion–Rest Graphs for 2D and 3D Motion of the Systems of Point Bodies
Now, we introduce the MRG for 2D and 3D motion of point masses.
Definition 2
(for the 3D motion of point masses). Let be point bodies moving in space, with positions The motion–rest graph (MRG) , where , and the coloring c is defined by:
The relation to “be at rest each relatively to other” is not transitive for 2D and 3D motion of point bodies. This is illustrated in Figure 9, depicting two rigid dumbbells and However, angle is time-dependent (see Figure 9).
Figure 9.
The figure illustrates the non-transitivity of the relation “to be at rest relative to each other” in 2D/3D motion of two dumbbells.
Point body is at rest relatively to , and body is at rest relatively to . However, point body moves relatively to . The situation is essentially different from that inherent in the 1D motion. The origin of this difference is geometric. In one-dimensional motion, the only rigid motion is translation, and constant separation between bodies necessarily implies equality of their velocities. Consequently, the relation “to be at rest relative to each other” becomes transitive. In two and three dimensions, rigid motions may include rotations. In rotating configurations, mutual distances between bodies remain constant even though their velocities are different. This additional rotational degree of freedom breaks the implication between constant separation and velocity equality, and therefore, the relation “to be at rest relative to each other” is generally not transitive. This leads to the non-transitive motion–rest graph, depicted in Figure 10. The graph is built for the system of five point bodies . The bodies are represented by the vertices numbered correspondingly . The rest–motion relations between the bodies are illustrated with the colors of the edges connecting the vertices (see Section 2.1). The MRG does not contain any monochromatic triangle. This is possible because the Ramsey number R(3, 3) = 6.
Figure 10.
Motion–rest non-transitive graph describing the motion of the five point bodies . There is no monochromatic triangle in the graph due to R(3, 3) = 6. Rust color depicts relative rest; cyan color depicts relative motion.
According to the Ramsey theorem, at least one monochromatic triangle will necessarily appear in the non-transitive MRG containing six vertices. Let us illustrate this with the following example. Consider the MRG depicted in Figure 10. To illustrate the six-vertex case, let us consider the time evolution in which one of the bodies represented in Figure 10 decays into two particles. Address the decay of the body into two particles and , namely , illustrated in Figure 11. We assume that particles are at rest relative to each other. The emerging MRG is shown in Figure 11.
Figure 11.
MRG illustrating the decay of the body , shown in Figure 10, into two particles and , namely . Particles are at rest, one relative to the other. Rust color depicts relative rest; cyan color depicts relative motion.
The graph shown in Figure 11 is the complete, bi-colored, Ramsey graph, containing six vertices. Thus, it inevitably contains at least one monochromatic triangle. Indeed, triangles (3,5,6) and (2,4,7) are monochromatic cyan. This reasoning leads to the following theorem:
Theorem 5.
Consider 2D or 3D motion of six point bodies . The bodies are represented by the vertices of the graph. The bodies/vertices are connected by the rust-colored edge when the bodies are at rest, each relatively to the other. Bodies that move relative to each other are connected by the cyan edge. Thus, the complete, bi-colored, rest–motion graph emerges. This graph is non-transitive and contains at least one monochromatic triangle.
The suggested approach may be extended to the sets of moving bodies and reference points, one of which may be the center of mass of the system. This leads to Theorem 6.
Theorem 6.
Consider the set of six point bodies performing the 2D or 3D motion. We prepare the motion–rest graph, whose vertices are the moving bodies and the center of mass of the system. The vertices are connected by the rust-colored edge when the bodies/centers of the masses are at rest, each relatively to the other. The vertices that move relative to each other are connected by the cyan edge. Thus, the complete, bi-colored, rest–motion graph emerges. This graph is non-transitive and contains at least one monochromatic triangle, whatever is the motion of the bodies.
Let us discuss the dynamic applications of the introduced theory. Consider the five vertices of the MRG graph depicted in Figure 10. This graph describes the motion of the moieties constituting the molecule of cyclopentane . The motion–rest graph supplied by cyclopentane contains no monochromatic triangle: the rust edges form the pentagon of covalent C–C bonds, while the cyan edges form the pentagon of nonbonded diagonals [22]. This graph-theoretic property has a direct kinematic implication. No three-carbon subset behaves as an independent rigid triangle, and no three-carbon subset undergoes a purely internal triangular deformation. Hence, the low-frequency eigenmodes of the molecule are not naturally localized on three-atom motifs but must be distributed over the entire five-membered ring. In this sense, the absence of monochromatic triangles favors collective puckering and pseudorotational modes, which is in agreement with the known vibrational behavior of cyclopentane [22].
Now, consider a molecular system whose motion–rest non-transitive graph (MRG) is constructed on six vertices corresponding to the nuclei of a cyclic molecule (e.g., cyclohexane C6H12), where covalent bonds define the rust edges forming a hexagonal cycle and nonbonded pairs define cyan edges (see Figure 11). Then, by the Ramsey theorem R(3, 3) = 6, the MRG necessarily contains monochromatic triangles. Since the rust subgraph is triangle-free, these triangles are necessarily cyan. The presence of such cyan triangles implies the existence of three-body subsets of atoms whose pairwise distances are not constrained to remain constant during internal motion. Consequently, the vibrational dynamics admit partially localized modes that are associated with these subsets. This prediction is supported by vibrational spectroscopy: infrared and Raman spectra exhibit both low-frequency collective modes (~200 cm−1) and distinct internal deformation modes (e.g., ~800 cm−1 corresponding to the CH2/ring modes and ~2850–2950 cm−1 C–H stretches), indicating partial localization of vibrational motion on subsets of atoms [23].
A realistic realization of the transition from a five-vertex to a six-vertex motion–rest graph (depicted in Figure 11) is provided by the decay of a neutral unstable particle inside a multiparticle event. For example, consider the five-particle configuration . The neutral Kaon , reconstructed experimentally as a , particle, subsequently decays according to [24]. The corresponding motion–rest graph then changes from a complete bi-colored graph on five vertices to a complete bi-colored graph on six vertices, namely Since R(3, 3) = 6, the resulting graph necessarily contains at least one monochromatic triangle. In a generic laboratory frame, this is a genuinely two- or three-dimensional configuration. Note that, unlike the illustrative splitting used above, the daughter particles in a genuine two-body decay are generally not at rest relative to each other; therefore, the edge joining them is typically cyan. Extension of the introduced approach for the analysis of deformation of continuous media is supplied in Appendix C.
2.5. Motion–Rest Graphs in General Relativity
The situation becomes different in general relativity. The relation “to be at rest relative to each other” is not necessarily stably transitive in general relativity, even in the case of effectively one-dimensional motion. Let us define precisely what is meant by one-dimensional motion in general relativity. In general relativity, space–time is a 4-dimensional Lorentzian manifold , where M is the set of all space–time events, and is the Lorentzian metric tensor [25,26]. We say that a set of particles performs one-dimensional motion if there exists a space-like curve γ, such that all particle worldlines remain confined to a time-like 2-dimensional worldsheet generated by this curve. In other words, there exists a space-like curve γ(s) and a parameter t, such that every particle worldline can be written as:
where is the coordinate along the same spatial curve, and parametrizes the worldsheet. The distance between particles numbered i and j must be defined on a space-like hypersurface :
where is the induced spatial metric and is the spatial curve connecting particles i and j taken within . The particles are at rest when holds. If and are constant in time in a neighborhood of , then is also constant in that neighborhood (by additivity of arc length along the same spatial curve γ). However, this property need not be preserved at later times . Thus, transitivity of rest may fail under dynamical evolution. An important example is the expanding universe (e.g., Friedmann–Lemaître–Robertson–Walker space–time), where physical distances between co-moving particles evolve in time. Hence, the relation “to be at rest relative to each other”, defined through constant mutual distance, is not necessarily stably transitive even for effectively one-dimensional motion.
This property need not be preserved even when the spatial metric is time-independent in a given foliation.
In general relativity, the transitivity of the relation “to be at rest” is not guaranteed, even when the spatial metric is time-independent. The fundamental geometric reason is that, in a generic space–time, there is no global rigid congruence of observers. Let be the 4-velocity field of a congruence, and let be the induced spatial metric (the projection tensor onto the local rest space orthogonal to . The condition for preservation of all mutual spatial distances within the congruence is:
where denotes the Lie derivative along , which is equivalent to vanishing expansion and shear of the congruence :
In the effectively one-dimensional case, the spatial metric reduces to a single component . The shear tensor vanishes identically in one dimension, and the only obstruction to the preservation of mutual distances is the expansion scalar θ. Thus, for one-dimensional motion, the condition for rest reduces to , i.e., the absence of expansion of the congruence. Thus, if , mutual distances are preserved along the flow, and the relation “to be at rest” defines a transitive (equivalence) relation, and we return to Theorems 1–3.
In the 3D case, congruences satisfying these conditions are Born-rigid. Only for Born-rigid congruences are all mutual spatial distances preserved along the flow; hence, the transitivity of “to be at rest relative to each other” holds only in these cases. In generic curved space–times, where expansion or shear is present, pairwise constancy of distances may fail to define an equivalence relation. Consequently, the relation “to be at rest relative to each other” generally fails to be stably transitive, even for effectively one-dimensional motion. In this case, the MRG is quantified by Theorem 5.
A sufficient geometric condition for transitivity is the existence of a time-like Killing vector field generating the congruence: such a flow preserves the metric and defines a stationary rest structure [27]. The Herglotz–Noether theorem shows that Born-rigid motions in relativity are extremely restricted—essentially those generated by Killing fields [27]. This strong geometric restriction has a direct interpretation for motion–rest graphs: rigid clusters correspond to exceptional symmetric situations, while generic relativistic dynamics produce heterogeneous graph structures. Thus, the interplay between space–time geometry and the combinatorial structure of motion–rest graphs provides a geometric origin for observed patterns of rest and motion in relativistic many-body systems.
2.6. Space–Time as the Motion–Rest Graph
Now, we propose a further conceptual step: the motion–rest graph (MRG) may be interpreted not merely as a kinematic descriptor of motion in a given space–time, but as an object that encodes the geometry of space–time itself. Consider a set of six reference points placed in a given gravitational field. At each reference point, we position a small test body. These bodies are assumed to be ideal probes: they interact only with the external gravitational field and do not interact with one another. Their motion is therefore governed entirely by the geometry of space–time; namely, freely falling test bodies follow geodesics. We define the relation of relative rest exactly as before: two bodies are said to be at rest relative to each other if the spatial distance between them, measured in their instantaneous co-moving frame, remains constant in time. Otherwise, they are in relative motion. This induces a complete bi-colored graph—the motion–rest graph—on the six bodies.
In this construction, the coloring of the edges is no longer arbitrary or externally imposed. It is determined entirely by the space–time geometry: if two nearby geodesics maintain constant separation, we connect the reference points with the rust edge; if their separation changes (geodesic deviation), we connect the reference points with the cyan edge. Thus, the MRG becomes a discrete probe of the metric structure. In general relativity, the relative motion of nearby test bodies is governed by the geodesic deviation equation:
where is the separation vector between neighboring worldlines, is the four-velocity, and is the Riemann curvature tensor. Equation (14) shows that curvature controls whether distances remain constant or change. The evolution of separation between neighboring geodesics is governed by the geodesic deviation equation, so the coloring is not arbitrary but is determined by the space–time geometry through the curvature tensor. In flat space–time (vanishing curvature), special families of worldlines with constant mutual distances (Born-rigid motion) can be constructed, and transitive clusters of relative rest become possible. In contrast, in a generic curved space–time, geodesic deviation causes separations to change, and cyan edges proliferate, leading to the breakdown of transitivity of relative rest.
Since the MRG is a complete bi-colored graph, Ramsey’s theorem implies that among any six test bodies/vertices there must exist a monochromatic triangle. In this context, such triangles acquire a geometric meaning: a rust triangle corresponds to a locally rigid cluster of worldlines, whereas a cyan triangle reflects irreducible tidal deformation encoded by curvature. Thus, space–time geometry is not described solely by a smooth metric tensor, but can also be represented through the structure of relations between test bodies. The motion–rest graph may therefore be viewed as a discrete, relational analog of the space–time metric, in which geometry emerges from the combinatorics of relative motion.
2.7. Transitivity of the State “To Be at Rest” in Quantum Mechanics
In the realm of quantum mechanics, the situation becomes subtle. In quantum mechanics, the definition of the relation “to be at rest” based on the constant separation between the particles cannot be used in the same way, as it was introduced in Section 2.1. The positions of particles are described by operators, and particles do not possess definite trajectories [28,29,30]. Moreover, due to the Heisenberg uncertainty relation, , a state in which the distance between particles is sharply defined for all times, would require complete uncertainty in their momenta [28,29,30]. Such states are highly nonphysical and cannot represent localized particles. Therefore, the classical definition of “to be at rest” based on the constancy of the distance between particles is not operationally meaningful in quantum mechanics. Instead, the notion of relative rest must be formulated using relative momentum. For particles moving along one spatial dimension, we define two particles being in the state “at rest relative to each other” as a state in which the relative velocity of the particles is zero. Exactly speaking, the particles and are at rest relative to each other if the state is an eigenstate (or narrow wavepacket) of with eigenvalue zero. Consider three particles A, B, and C on a line. We define the operators:
which satisfy We can prepare the state when particles A and B are at rest , and we can prepare the state when particles B and C are at rest . Therefore, formally, it is possible to realize the state where and where . Thus, at the level of operator algebra, the relation “to be at rest” appears transitive. However, there exists an inevitable quantum limitation: the conditions and imply which requires the state to be sharply defined in relative momenta. By the uncertainty principle, this leads to complete delocalization in the relative coordinates. Such states cannot represent localized particles and are non-normalizable in the ideal limit.
Therefore, there exists no physical state (except trivial plane waves with infinite delocalization) satisfying both conditions operationally. Hence, pairwise “rest” relations are contextual and non-transitive at the level of realizable states. Thus, even in the case of 1D motion, the MRG is a non-transitive graph, and Theorem 3 is applicable.
Now, consider the MRG as it is seen in the system of the center of mass of three identical quantum particles. Consider three identical particles moving on a line, with position operators and momentum operators . Introduce the center-of-mass coordinate and two independent relative coordinates:
The third relative coordinate is not independent but satisfies:
Similarly, for the conjugate relative momenta, we obtain:
so that,
Equations (17) and (18) express the essential geometric fact: in a three-particle system, there exist only two independent relative variables. Therefore, if the state satisfies
then necessarily:
Thus, at the purely kinematic level, the relation “to be at rest” is formally transitive. However, the same change in variables also reveals the quantum limitation. Sharp relative rest means sharp values of the relative momenta ; hence, by the uncertainty relations:
Therefore, the more precisely the three pairwise rest conditions are imposed, the less definite the relative separations become. In the ideal limit exactly, the state is completely delocalized in the relative coordinates. Such a state does not describe three localized particles at fixed mutual distances, but rather a non-normalizable collective momentum state. Hence, quantum mechanics preserves transitivity only at the level of exact kinematic eigenstates, while for physically realizable localized states, the notion of pairwise rest becomes only approximate and operational. In this sense, the quantum notion of “being at rest relative to each other” is weaker than in classical mechanics. Exact transitivity survives only for delocalized ideal states, whereas for physically realizable localized states, the notion of mutual rest is only approximate. Thus, quantum mechanics preserves the transitivity of “being at rest” at the level of operator identities, while for physically realizable localized states, it becomes only approximate, leading to effectively non-transitive motion–rest graphs.
3. Discussion
3.1. Main Results Presented in the Paper
The present work introduces a graph-theoretical framework for analyzing motion and rest in many-body systems. The essential idea is to regard physical bodies as vertices of a complete bi-colored graph and to color each edge according to a kinematic relation: “rust” if two bodies are at rest relative to each other or “cyan” if they move relative to each other. The coloring is dichotomic: the introduced relations are distinguishable and mutually exclusive. At first glance, this may seem to be a simple visual representation of pairwise kinematic relations. However, the results obtained here show that the emerging graphs are far from arbitrary. Their structure is strongly constrained by the logical properties of the underlying physical relation and, consequently, by the geometry of the space–time in which motion is defined.
The first principal result of this paper is that the relation “to be at rest relative to each other” has a dimension-dependent logical status. In one-dimensional classical motion and in one-dimensional inertial motion in special relativity, this relation is reflexive, symmetric, and transitive. Therefore, in this regime, relative rest defines an equivalence relation. This conclusion is not merely formal. It implies that the set of moving bodies decomposes into disjoint rest-clusters, namely equivalence classes of bodies whose mutual distances remain constant in time. Graph-theoretically, this means that the rust subgraph is a disjoint union of complete cliques, while all edges between distinct cliques are cyan. Thus, for the 1D motion, the motion–rest graph is completely determined by a partition of the set of bodies into equivalence classes. In this sense, the kinematics of one-dimensional many-body motion possesses a hidden combinatorial order.
This observation provides the physical meaning of Theorems 1–3. These theorems do not merely restate Ramsey’s theorem in kinematic language. Rather, they show that in the 1D motion, the admissible colorings form a highly restricted subclass of all complete bi-colored graphs. The restriction arises from the transitivity of rest. Consequently, the appearance of monochromatic triangles for five vertices is not a generic combinatorial accident, but the inevitable outcome of combining a transitive rest relation with a non-transitive motion relation. In other words, the monochromatic substructures appearing in the graph reflect the genuine physical organization of the system. Rust triangles correspond to rigid or co-moving clusters; cyan triangles correspond to triples of bodies that are mutually in relative motion. Thus, Ramsey-type inevitability acquires a direct kinematic interpretation.
A particularly important point is that the graph structure is frame-independent. The coloring depends only on the constancy or non-constancy of mutual distances and therefore is relational rather than absolute. This is conceptually significant. Ordinary descriptions of motion depend strongly on the chosen frame of reference, but the motion–rest graph captures only pairwise relational content. In this respect, the graph-theoretical description is closer in spirit to relational mechanics than to naive coordinate-based kinematics. This frame-independence is especially important in special relativity, where a motion that is one-dimensional in one inertial frame may appear two- or three-dimensional in another. Nevertheless, the coloring of the graph remains unchanged. Hence, the MRG extracts from kinematics precisely the part that survives changes of inertial frame.
The role of equivalence classes in the one-dimensional case deserves special emphasis. Equivalence classes are fundamental throughout physics because they group together objects or configurations that are indistinguishable relative to a specified physical criterion. In gauge theory, gauge-related potentials form equivalence classes; in quantum mechanics, vectors differing by a global phase belong to the same physical state; in statistical mechanics, many microstates correspond to the same macrostate. In the present work, for 1D inertial motion, bodies that are at rest relative to one another form such equivalence classes. This gives the motion–rest graph a structure that is mathematically natural and physically transparent. The graph is not just a combinatorial object; it is the graphical manifestation of a partition of the system into dynamically meaningful clusters.
The situation changes qualitatively in two and three dimensions. Here, the relation “to be at rest relative to each other,” defined by constant mutual distance, is generally no longer transitive. The deep reason is geometric: in dimensions higher than one, constant separation does not imply identical velocities because rigid rotational motion becomes possible. In one dimension, the only rigid motion is translation, whereas in two and three dimensions, rigid motions can include rotation. This additional degree of freedom breaks the equivalence between the constancy of distance and equality of velocities. Therefore, the rust relation ceases, in general, to define an equivalence relation. As a result, the structure of the motion–rest graph is no longer that of a complete multipartite graph induced by a partition. This marks a sharp conceptual transition between one-dimensional and higher-dimensional kinematics.
This dimensional transition is reflected in the Ramsey threshold. For one-dimensional motion, because rust is transitive, monochromatic triangles are already unavoidable for five vertices. By contrast, in generic two- and three-dimensional motion, where rust is non-transitive, one needs six vertices, in accordance with the classical Ramsey number R(3, 3) = 6. This difference is physically meaningful. It shows that transitivity is not a minor logical detail but a structural property with direct combinatorial consequences. The lower threshold in the one-dimensional case is a manifestation of the extra order imposed by transitivity; the higher threshold in two and three dimensions reflects the greater geometric freedom of motion.
The examples based on rigid dumbbells, rigid triples, and star-centered graphs show that the theory has a clear physical interpretation. Rust subgraphs correspond to rigid clusters or co-moving structures, while cyan edges encode dynamical separation between such clusters. The presence of the center of mass as a distinguished vertex is also illuminating. It shows that the formalism can naturally incorporate reference points that are not material bodies but are dynamically meaningful constructions. In this sense, the framework is flexible: it can handle mixed sets of particles and privileged reference points, provided the motion–rest relation is defined consistently. Theorems 4 and 6 demonstrate that adding the center of mass often reveals hidden monochromatic structures that may not be immediately apparent in the body-only representation. The extension to the motion of infinite sets of material points is supplied in Appendix D.
3.2. Extensions to General Relativity and Quantum Mechanics
The extension to general relativity further clarifies the geometric foundations of the formalism. In curved space–time, the notion of being at rest relative to each other is more delicate because spatial distance itself depends on the choice of space-like hypersurface and on the congruence of observers. The analysis given in Section 2.5 shows that in general relativity, transitivity of rest is not guaranteed, even for effectively one-dimensional motion. The fundamental reason is the absence, in generic space–times, of a global rigid congruence. Only in exceptional situations, such as Born-rigid congruences or flows generated by a time-like Killing vector field, are all mutual spatial distances preserved consistently. Thus, from the viewpoint of motion–rest graphs, rigid rust-clusters in general relativity correspond not to generic behavior but to highly constrained geometric situations. This observation gives the graph-theoretical formalism a clear geometric interpretation: non-transitivity of rust in relativistic systems reflects the intrinsic dynamical structure of space–time itself.
The quantum-mechanical extension leads to a different but equally instructive conclusion. In quantum mechanics, the classical definition of relative rest through constant particle separation loses its direct meaning because particles do not possess definite trajectories. The natural replacement is to define relative rest through vanishing relative momentum. At the formal operator level, this relation is transitive: if
In this sense, the operator algebra preserves the transitivity of rest. However, the physically realizable content of this statement is limited by the uncertainty principle. Exact relative rest requires sharp relative momenta, and therefore, implies complete delocalization of the conjugate relative coordinates. The center-of-mass and relative-coordinate formulation developed in Section 2.3 and Section 2.7 makes this especially transparent: only two relative coordinates are independent, and exact vanishing of the conjugate relative momenta forces infinite uncertainty in relative separations. Hence, exact transitivity survives only for idealized, non-normalizable states. For localized physical states, pairwise rest can only be approximate and operational. Therefore, in the quantum domain, the motion–rest graph becomes effectively non-transitive. This is an important conceptual result: quantum mechanics preserves the algebraic skeleton of transitivity, but undermines its classical operational realization.
From a broader perspective, the present work suggests that motion–rest graphs provide a bridge between logic, geometry, and combinatorics. The logical properties of the relation “to be at rest relative to each other” determine the admissible graph structure; the geometry of motion determines whether those logical properties hold; and Ramsey-type combinatorics then dictates which substructures must inevitably appear. The resulting picture is appealing because it shows that unavoidable graph patterns in many-body systems are not merely abstract mathematical consequences but reflect concrete physical restrictions. In this sense, the graph-theoretical language reveals hidden order in kinematics.
The framework also suggests several possible generalizations. First, one may study multicolored motion graphs in which pairwise relations are refined beyond the simple dichotomy rest/motion (see Appendix B). For example, one could distinguish converging motion, diverging motion, uniform co-motion, rigid rotational coupling, or bounded oscillatory relative motion. Such refinements may lead to richer Ramsey-type phenomena. Second, the present treatment is purely kinematic; an important next step would be to incorporate dynamical laws and investigate how equations of motion constrain the time evolution of the graph. Third, continuous media, deformable bodies, or field configurations may be represented by infinite or time-dependent graph analogs. Fourth, the relation between motion–rest graphs and symmetry groups deserves further study, since rigid clusters are naturally associated with isometries and conserved structures. Finally, it would be interesting to explore whether analogous graph descriptions can be developed for systems in which “rest” is defined not by spatial distance but by constancy of more abstract relational quantities, such as phase, gauge connection, or quantum correlation.
3.3. The Limitations of the Introduced Approach
The limitations of the present approach should also be noted. The notion of relative rest adopted here is purely pairwise and kinematic. It does not encode forces, causality, energy exchange, or stability. Thus, two systems with very different dynamics may generate the same motion–rest graph. The formalism should therefore be understood as a coarse-grained relational description rather than a complete dynamical theory. In addition, in general relativity and quantum mechanics, the very notion of distance or relative rest is subtler than in classical mechanics, and the corresponding graph interpretation depends on the operational definition adopted. Nevertheless, these limitations do not weaken the central conclusion of the paper. On the contrary, they show that the graph-theoretical representation isolates a minimal but robust relational core common to diverse physical settings.
In conclusion, the motion–rest graph introduced here provides a new way to think about kinematics. For one-dimensional classical and relativistic motion, the relation of relative rest defines equivalence classes and induces a highly ordered semi-transitive graph structure. In higher-dimensional classical motion, in generic general-relativistic settings, and in operationally realizable quantum states, this transitivity is lost, and the graph becomes genuinely non-transitive. In all cases, Ramsey-type constraints imply that sufficiently large systems must contain unavoidable monochromatic substructures. Thus, the paper demonstrates that the interplay between physical relations, logical properties, and combinatorial inevitability yields a nontrivial and fruitful framework for analyzing many-body motion. The motion–rest graph is therefore not only a convenient visualization tool, but also a structural invariant of relational kinematics.
4. Conclusions
In this work, we introduced a graph-theoretical framework for analyzing motion and rest in systems of point bodies. Bodies are represented as vertices of a complete, bi-colored graph whose edges encode pairwise kinematic relations: edges are colored rust when mutual distance remains constant and cyan otherwise. The resulting motion–rest graph (MRG) provides a relational, frame-independent kinematic description of many-body motion.
The central result is that the combinatorial structure of the MRG is dictated by the logical properties of the relation “to be at rest relative to each other.” In one-dimensional classical motion and in one-dimensional inertial motion in special relativity, this relation is reflexive, symmetric, and transitive, and therefore defines an equivalence relation. The system decomposes into rest-clusters of bodies with constant mutual distances. Graph-theoretically, rust edges form complete cliques corresponding to these clusters, while edges between clusters are necessarily cyan. The MRG is thus a semi-transitive complete bi-colored graph determined by this partition.
This structure has direct combinatorial consequences. For one-dimensional motion, any MRG with five vertices necessarily contains a monochromatic triangle. Physically, such triangles correspond either to rigid clusters or to triples of bodies moving pairwise relative to each other. Thus, Ramsey-type inevitability acquires a clear kinematic interpretation, reflecting the coexistence of a transitive relation (rest) with a non-transitive one (motion).
In two- and three-dimensional motion, the situation changes qualitatively. The relation of relative rest, defined via constant distance, is generally not transitive due to rigid rotations. The MRG becomes non-transitive, and the Ramsey threshold reduces to the classical value R(3, 3) = 6: for six point bodies, at least one monochromatic triangle must appear.
The framework was extended to systems that included reference points (e.g., center of mass), leading to star-centered MRGs with analogous Ramsey-type constraints. Extensions to infinite systems, continuous media, and issues of stability were also discussed.
In relativistic and quantum regimes, further modifications arise. In general relativity, transitivity of relative rest fails in general due to the dependence of spatial distances on space–time geometry and observer congruences; it is preserved only for special cases such as Born-rigid motions or flows generated by time-like Killing fields. In quantum mechanics, the classical distance-based notion of rest loses operational meaning; a formulation in terms of relative momentum operators restores formal transitivity, but the uncertainty principle implies that exact relative rest requires complete delocalization. For localized states, the relation becomes effectively non-transitive.
Overall, the motion–rest graph is governed by the interplay between kinematics, geometry, and combinatorial constraints. Ramsey-type ordered substructures emerge naturally as a consequence of the logical structure of relational kinematics. The MRG thus provides a unifying conceptual tool for analyzing many-body motion in classical, relativistic, and quantum systems.
Future work may extend this approach to multicolored relational graphs and time-evolving graph dynamics. More broadly, the results suggest that many-body motion is shaped not only by dynamical laws but also by intrinsic structural constraints: space–time determines the logical properties of relational motion, which, in turn, restricts admissible combinatorial structures. The motion–rest graph, therefore, reveals a nontrivial unity between physics, logic, and combinatorics.
Funding
This research received no external funding.
Data Availability Statement
Data are contained within the article.
Acknowledgments
The author is thankful to the anonymous reviewers for their extremely helpful reviewing of the manuscript.
Conflicts of Interest
The author declares no conflicts of interest.
Abbreviations
The following abbreviation is used in this manuscript:
| MRG | Motion–Rest Graph |
Appendix A
Theorem A1.
Let C be a fixed geodesic curve endowed with an arc-length parameter s. Suppose that point bodies move along the same geodesic C, so that the position of body is given by . Define two bodies and to be at rest relative to each other if their arc-length separation along C remains constant in time, namely:
Then, the relation “to be at rest relative to each other” is reflexive, symmetric, and transitive. Therefore, it defines an equivalence relation on the set of bodies moving along C. Consequently, the corresponding motion–rest graph is semi-transitive: rust edges form disjoint complete cliques, and edges joining different cliques are cyan.
Proof.
Reflexivity is immediate, since for every body : . □
Symmetry is also immediate, because:
Now, prove transitivity. Suppose that is at rest relative to , and is at rest relative to . Then:
Since all bodies move on the same geodesic C, which is intrinsically one-dimensional, the arc-length coordinate s provides a one-dimensional ordering along the curve. Therefore, the separation of and is determined by the additivity of arc-length along the same curve:
Hence, if both and are constant in time, then is also constant in time. Therefore:
Hence, the relation “to be at rest relative to each other” is reflexive, symmetric, and transitive, and therefore defines an equivalence relation. The rest of the graph-theoretical conclusions follow exactly as in the case of rectilinear one-dimensional motion.
The essential reason for transitivity is not straightness in the ambient space, but the intrinsic one-dimensionality of motion along a single geodesic, which allows pairwise separations to be described by one arc-length coordinate.
In general relativity, even if particles “move along the same curve,” there is no globally consistent arc-length scalar coordinate s(t) that simultaneously measures distances between all pairs. Transitivity of rest is equivalent to the existence of a global one-dimensional coordinate describing mutual separations. General relativity generically lacks such a structure; hence, transitivity fails.
Appendix B. Analysis of the Stability of Transitivity for the 1D Motion
In order to analyze the stability of transitivity of the 1D motion, we introduce the notion of the “ε-rest”, or approximate rest. Theorems 1–4 are exact statements based on the exact transitivity of the relation “to be at rest relative to each other” in one-dimensional motion. In realistic systems, however, one often encounters small fluctuations, quasi-rigid motion, finite observation windows, or measurement noise. In such situations, it is natural to replace exact rest by ε-rest on a time interval , meaning that the fluctuation of the pairwise distance satisfies
We say that bodies and j are in ε-rest if This is the definition of ε-rest. For motion along the same line, or more generally along the same geodesic with arc-length coordinate s, one has:
Hence, if pairs and are approximately at rest, with , . Then, necessarily:
Therefore, approximate ε-rest is not exactly transitive, but it is Lipschitz-stable: two ε-rest links imply one 2ε-rest link. More generally, along a chain of m consecutive approximate-rest relations, the cumulative deviation is bounded by mε. Thus, the semi-transitive structure survives in an approximate sense. Therefore, approximate rest is stable in a quantitative sense: if two links are ε-rest, the third is at worst 2ε-rest. Thus, when a finite gap separates small intra-cluster fluctuations from larger inter-cluster relative motion, the thresholded motion–rest graph retains the same semi-transitive structure and the Ramsey-type conclusions remain robust. By contrast, if this scale separation is absent, the graph becomes only approximately semi-transitive, and the exact five-vertex guarantee need not hold.
This leads to the following physical interpretation. If the system has well-separated scales, namely if all intra-cluster fluctuations satisfy , while all inter-cluster relative motions satisfy for some margin δ > 0, then the binary coloring is robust under perturbations of size smaller than δ/2. In that regime, the same partition into rest-clusters is recovered after thresholding, and the 1D theorems remain valid. If no such gap exists, then weak perturbations may change the coloring of some edges. In that case, the graph is only approximately semi-transitive, and the exact five-vertex guarantee is lost. One then no longer has a strict theorem of the type proved in the paper, but rather a near-semi-transitive graph whose monochromatic triangles are expected to be stable only statistically or approximately. In the worst-case combinatorial sense, even a small number of edge flips may destroy exact semi-transitivity. Therefore, the exact theorem is not uniformly robust to arbitrary adversarial perturbations. What is robust is the physically meaningful situation in which perturbations are small compared with the gap separating “almost rigid” pairs from genuinely moving pairs.
In other words, there are two different notions of robustness:
- (i)
- Logical robustness: exact transitivity is brittle; once it is broken, the exact theorem no longer applies as stated.
- (ii)
- Physical robustness: if relative-rest clusters are separated by a finite observational gap, then small noise or quasi-rigid deformations do not change the thresholded coloring, and the same graph-theoretic conclusions survive.
This distinction is especially important for the applications discussed in this paper. For example, in realistic molecular or mechanical systems, one rarely has perfect rigidity, but one often has a natural hierarchy: bonded or rigidly correlated pairs have very small distance fluctuations, uncorrelated or independently moving pairs have much larger fluctuations. Then, a thresholded motion–rest graph remains meaningful and stable. The monochromatic triangles predicted by the semi-transitive structure should therefore be understood not as artifacts of exact mathematical idealization, but as robust signatures of systems possessing sufficiently clear cluster separation. The same observation applies to the general-relativistic and quantum extensions. In both settings, exact transitivity is generically lost, but approximate-rest relations may still persist over finite scales or finite times. In such cases, the graph should be interpreted as an effective or coarse-grained motion–rest graph, valid within a specified tolerance and observational window.
Appendix C. Motion–Rest Graphs Emerging for Deformable Continuous Media
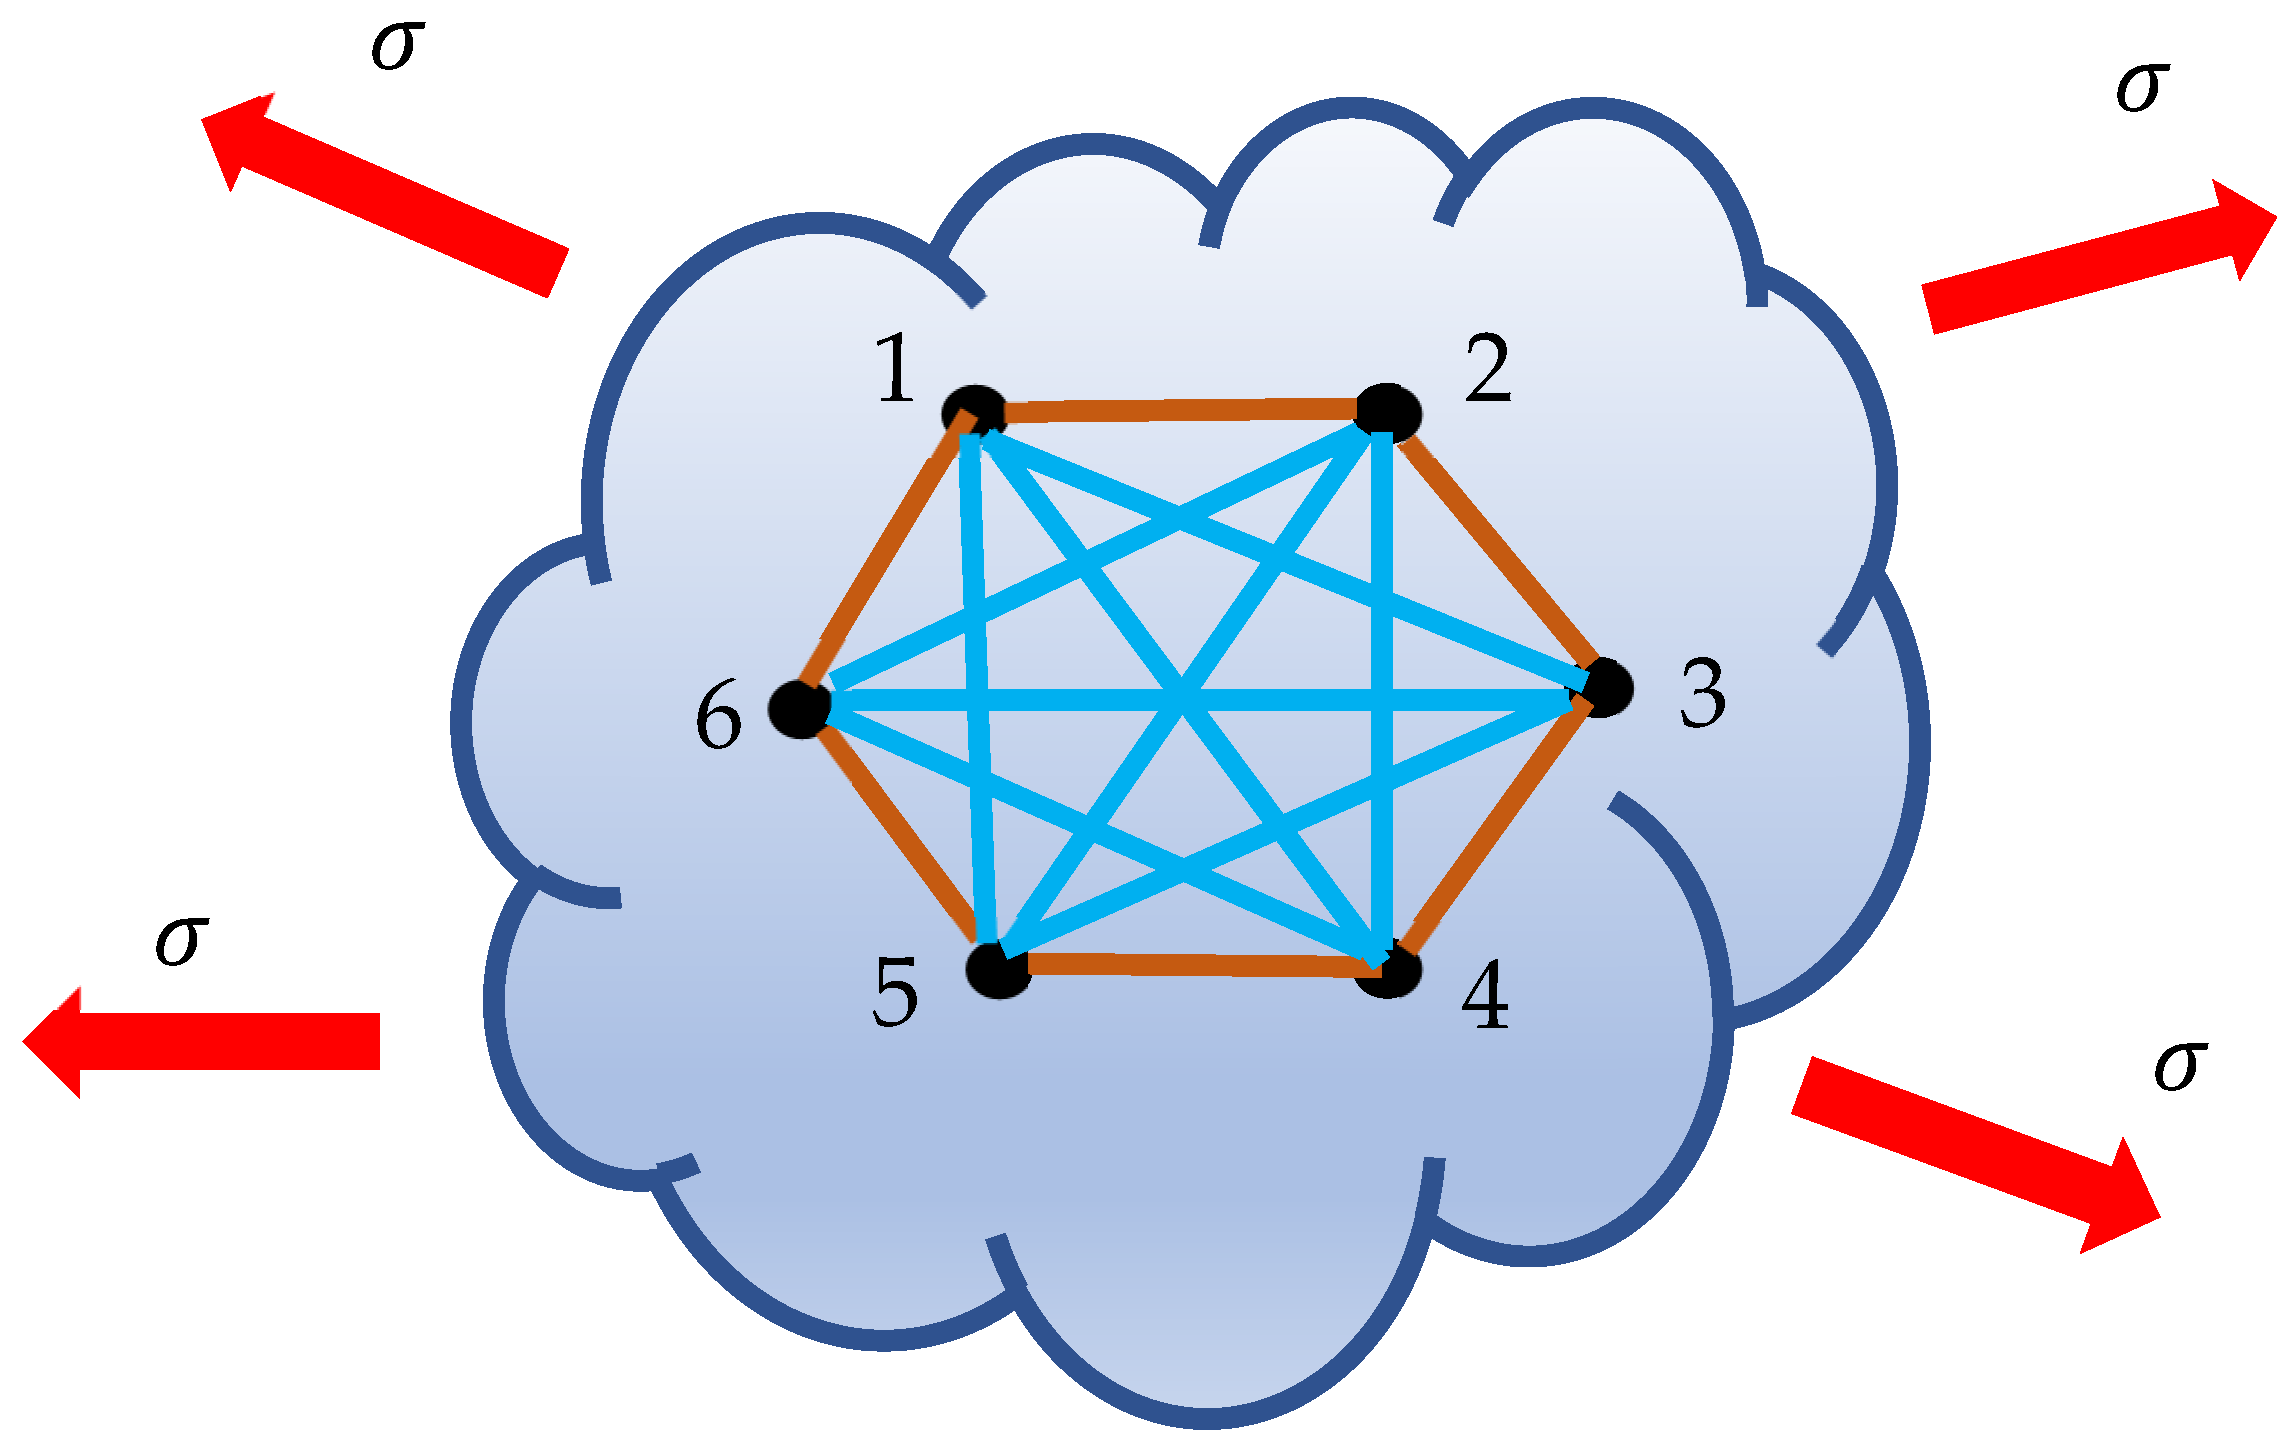
The developed approach may be useful for the analysis of the strain of deformable continuous media (not necessarily elastic). Consider the deformable body depicted in Figure A1. The deformation is two- or three-dimensional. Points {1,2…6} are fixed within the body and then the stress σ is applied (see Figure A1). The vertices of the hexagon {1,2…6} are at rest relative to each other, and they are connected by the rust edges. However, the hexagon {1,2…6} is not rigid, and the points are displaced relative to each other. We connect the moving points with cyan links; the coloring of the links is described in Section 2.1.
Figure A1.
Six points labeled located within the deformable continuous medium are depicted. Stress is applied. Points are displaced under the deformation, and the color of the links connecting the points is established in Section 2.1. Monochromatic cyan triangles {1,3,5} and {2,4,6} are recognized in the graph. According to the Ramsey theorem appearance of at least one monochromatic triangle in the graph is independent of the kind of deformation, i.e., the deformation may be elastic or plastic.
This analysis yields the following theorem:
Theorem A2.
Ramsey inevitability in motion–rest graphs of deformable media.
Let be six material points embedded in a deformable continuous medium subjected to an arbitrary deformation (elastic or plastic). Let the motion–rest graph be defined as in Section 2.1, where vertices correspond to the points and edges are colored rust if the pairwise distance is constant in time and cyan otherwise.
Then, the graph G necessarily contains at least one monochromatic triangle (either rust or cyan).
Remark A1.
In a deformable 2D or 3D medium, the relation “to be at rest relative to each other” is generically non-transitive.
Appendix D. Infinite Motion-Rest Graphs
Consider now an infinite but countable system of moving material points/particles . The particles are moving in a 2D or 3D space. The particles form the vertices of the infinite, bi-colored graph. The vertices/particles are connected by the rust link when the particles are at rest relative to each other. The vertices/particles are connected by the cyan link when the particles move relative to each other. Figure A2 represents the graph corresponding to the instantaneous snapshot of the motion. According to the Ramsey infinite theorem, the infinite monochromatic (violet or orange) clique will necessarily appear in the graph [31,32].
Let us formulate the infinite Ramsey theorem rigorously.
Figure A2.
An infinite, however countable system of moving material points/particles is depicted. The particles form the vertices of the infinite, bi-colored graph. The vertices/particles are connected by the rust link when the particles remain at the same distance. The vertices/particles are connected by the cyan link when the particles move relative to each other. An infinite monochromatic (rust or cyan) clique will necessarily appear in the graph.
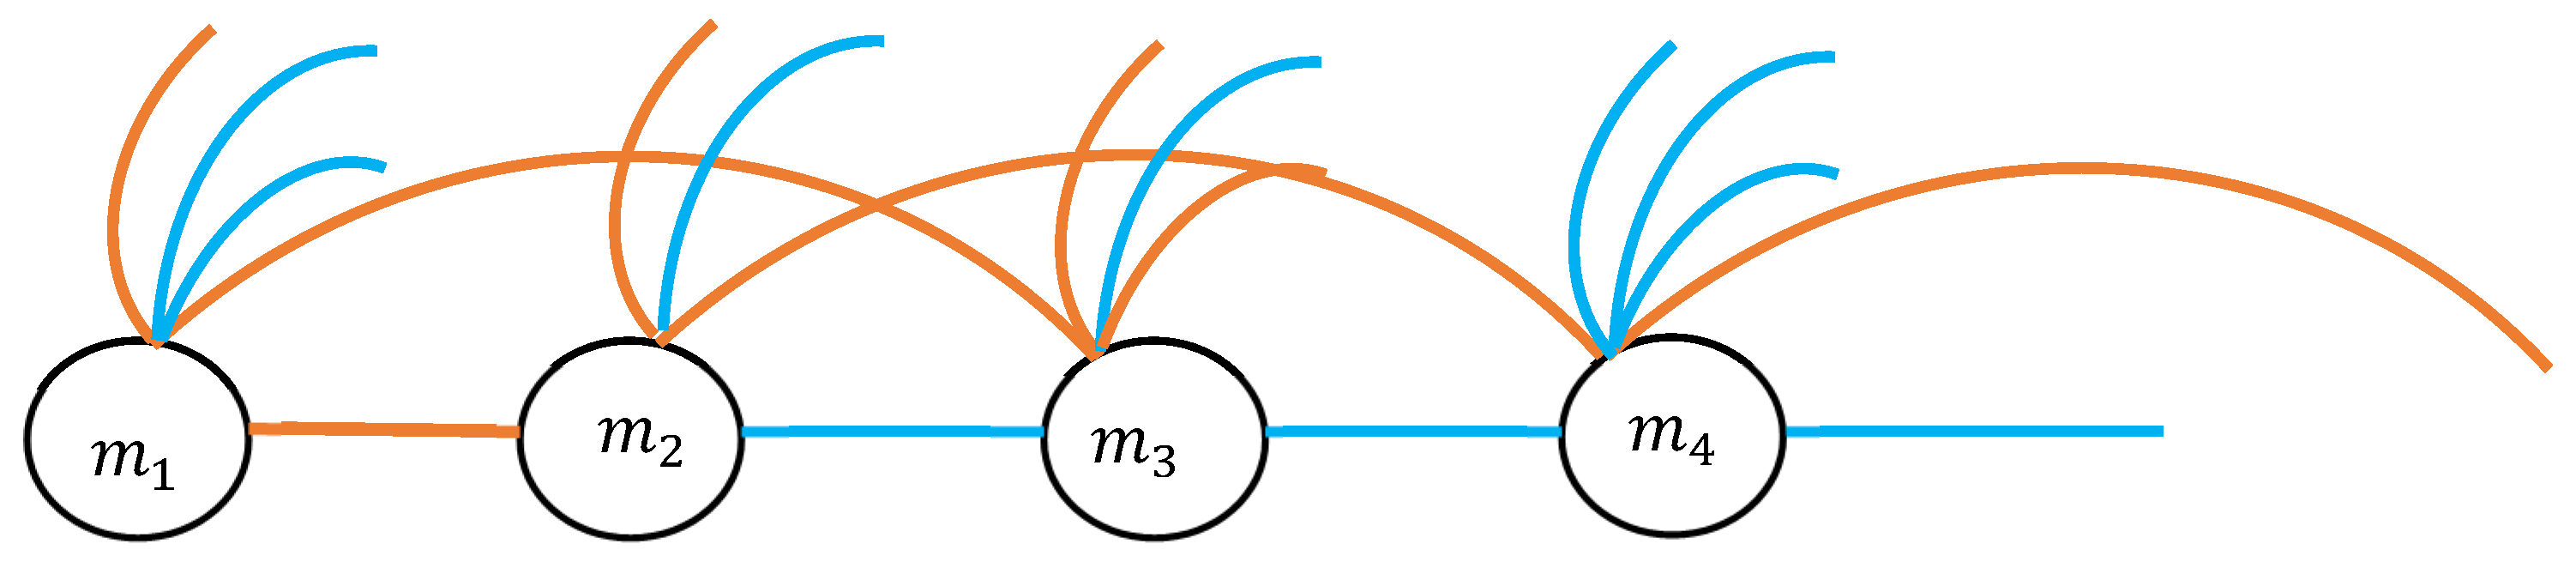
Let denote the complete colored graph on the vertex set N. For every , if we color the edges of with distinguishable colors, then there must be an infinite monochromatic clique present [31,32]. An infinite monochromatic clique in a colored graph is a subset of vertices that are all pairwise adjacent (i.e., form a clique) and whose edges are all the same color in a given edge-coloring of the graph. The infinite Ramsey theorem re-formulates the seminal Dirichlet pigeonhole principle, which states that if there exists n pigeonholes containing pigeons, one of the pigeonholes necessarily must contain at least two pigeons [31,32]. Thus, the monochromatic clique will necessarily appear in the kinematic graph, shown in Figure A2. In other words, there exists an infinite subset of particles that are either pairwise at rest relative to each other or pairwise in relative motion. The coloring of the graph is time-dependent but frame-independent. An infinite Ramsey theorem does not predict the exact color of the monochromatic clique. Thus, Theorem A3 is formulated:
Theorem A3.
Let be a countable set of point bodies moving in or and let be the corresponding motion–rest graph, where , and the coloring c is defined by:
Then, there exists an infinite subset such that all edges between the vertices of
have the same color.
Equivalently, the motion–rest graph contains an infinite monochromatic clique (either entirely rust or entirely cyan). In any infinite many-body system, there necessarily exists an infinite collection of particles that are either mutually at rest relative to each other (constant pairwise distances) or mutually in relative motion.
References
- Eschrig, G. Topology and Geometry for Physics; Springer: Berlin/Heidelberg, Germany, 2011. [Google Scholar]
- Nakahara, M. Geometry, Topology and Physics, 2nd ed.; CRC Press: Boca Raton, FL, USA, 2003. [Google Scholar]
- Baez, J.; Stay, M. Physics, Topology, Logic and Computation: A Rosetta Stone. In New Structures for Physics; Coecke, B., Ed.; Lecture Notes in Physics; Springer: Berlin/Heidelberg, Germany, 2010; Volume 813. [Google Scholar] [CrossRef] [Scilit]
- Coecke, B.; Paquette, É. Categories for the Practising Physicist. In New Structures for Physics; Coecke, B., Ed.; Lecture Notes in Physics; Springer: Berlin/Heidelberg, Germany, 2010; Volume 813. [Google Scholar] [CrossRef] [Scilit]
- de Gois, C.; Hansenne, K.; Gühne, O. Uncertainty relations from graph theory. Phys. Rev. A 2023, 107, 062211. [Google Scholar] [CrossRef] [Scilit]
- Xu, Z.-P.; Schwonnek, R.; Winter, A. Bounding the Joint Numerical Range of Pauli Strings by Graph Parameters. PRX Quantum 2024, 5, 020318. [Google Scholar] [CrossRef] [Scilit]
- Kottos, T.; Smilansky, U. Quantum Chaos on Graphs. Phys. Rev. Lett. 1997, 79, 4794–4797. [Google Scholar] [CrossRef] [Scilit]
- Cabello, A.; Severini, S.; Winter, A. Graph-Theoretic Approach to Quantum Correlations. Phys. Rev. Lett. 2014, 112, 040401. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Estrada, E. Graph and network theory in physics. arXiv 2013, arXiv:1302.4378. [Google Scholar] [CrossRef] [Scilit]
- Lesne, A. Complex Networks: From Graph Theory to Biology. Lett. Math. Phys. 2006, 78, 235–262. [Google Scholar] [CrossRef] [Scilit]
- Graham, R.L.; Rothschild, B.L.; Spencer, J.H. Ramsey Theory, 2nd ed.; Wiley-Interscience Series in Discrete Mathematics and Optimization; John Wiley & Sons, Inc.: New York, NY, USA, 1990; pp. 10–110. [Google Scholar]
- Graham, R.; Butler, S. Rudiments of Ramsey Theory, 2nd ed.; American Mathematical Society: Providence, RI, USA, 2015; pp. 7–46. [Google Scholar]
- Di Nasso, M.; Goldbring, I.; Lupini, M. Nonstandard Methods in Combinatorial Number Theory; Lecture Notes in Mathematics; Springer: Berlin, Germany, 2019; Volume 2239. [Google Scholar]
- Katz, M.; Reimann, J. Introduction to Ramsey Theory: Fast Functions, Infinity, and Metamathematics; Student Mathematical Library; American Mathematical Society: Providence, RI, USA, 2018; Volume 87, pp. 1–34. [Google Scholar]
- Bormashenko, E. Temporal Ramsey Graphs: The Ramsey Kinematic Approach to the Motion of Systems of Material Points. Dynamics 2025, 5, 11. [Google Scholar] [CrossRef] [Scilit]
- Musielak, Z.E.; Quarles, B. The three-body problem. Rep. Prog. Phys. 2014, 77, 065901. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Marchal, C. The Three-Body Problem; Elsevier: Amsterdam, The Netherlands, 1990. [Google Scholar]
- Szebehely, V.G.; Mark, H. Adventures in Celestial Mechanics, 2nd ed.; Wiley: New York, NY, USA, 1998. [Google Scholar]
- Bormashenko, E.; Frenkel, M. The Three-Body Problem: The Ramsey Approach and Symmetry Considerations in the Classical and Quantum Field Theories. Symmetry 2025, 17, 1404. [Google Scholar] [CrossRef] [Scilit]
- Gilevich, A.; Shoval, S.; Nosonovsky, M.; Frenkel, M.; Bormashenko, E. Converting Tessellations into Graphs: From Voronoi Tessellations to Complete Graphs. Mathematics 2024, 12, 2426. [Google Scholar] [CrossRef] [Scilit]
- Motzkin, T.S.; Straus, E. Maxima for graphs and a new proof of a theorem of Turán. Can. J. Math. 1965, 17, 533–540. [Google Scholar] [CrossRef] [Scilit]
- Kowalewski, P.; Frey, H.-M.; Infanger, D.; Leutwyler, S. Probing the Structure, Pseudorotation, and Radial Vibrations of Cyclopentane by Femtosecond Rotational Raman Coherence Spectroscopy. J. Phys. Chem. A 2015, 119, 11215–11225. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Pickett, H.M.; Strauss, H.L. Conformational structure, energy, and inversion rates of cyclohexane and some related oxanes. J. Am. Chem. Soc. 1970, 92, 7281–7290. [Google Scholar] [CrossRef] [Scilit]
- Rochester, G.D.; Butler, C.C. Evidence for the Existence of New Unstable Elementary Particles. Nature 1947, 160, 855–857. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Landau, L.D.; Lifshitz, E.M. The Classical Theory of Fields, 4th ed.; Pergamon Press: Oxford, UK, 1975. [Google Scholar]
- Wald, R.M. General Relativity; University of Chicago Press: Chicago, IL, USA, 1984. [Google Scholar]
- Epp, R.J.; Mann, R.B.; McGrath, P.L. Rigid motion revisited: Rigid quasilocal frames. Class. Quantum Grav. 2009, 26, 035015. [Google Scholar] [CrossRef] [Scilit]
- Landau, L.D.; Lifshitz, E.M. Quantum Mechanics. Non-Relativistic Theory, Volume 3 of Course of Theoretical Physics, 3rd ed.; Pergamon Press: Oxford, UK, 1965. [Google Scholar]
- Bohm, D. Quantum Theory; Dover Publications: New York, NY, USA, 1989. [Google Scholar]
- Messiah, A. Quantum Mechanics; Dover Books on Physics; Dover Publications: Mineola, NY, USA, 2014. [Google Scholar]
- Carlson, T.J.; Simpson, S.G. A dual form of Ramsey’s Theorem. Adv. Math. 1984, 53, 265–290. [Google Scholar] [CrossRef] [Scilit]
- Robertson, A. Fundamentals of Ramsey Theory; CRC Press: Boca Raton, FL, USA, 2021. [Google Scholar]
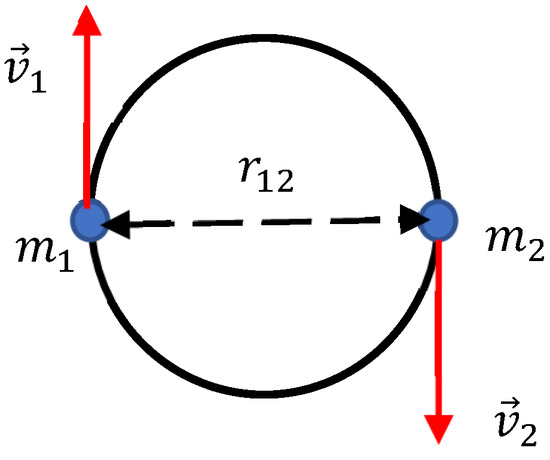
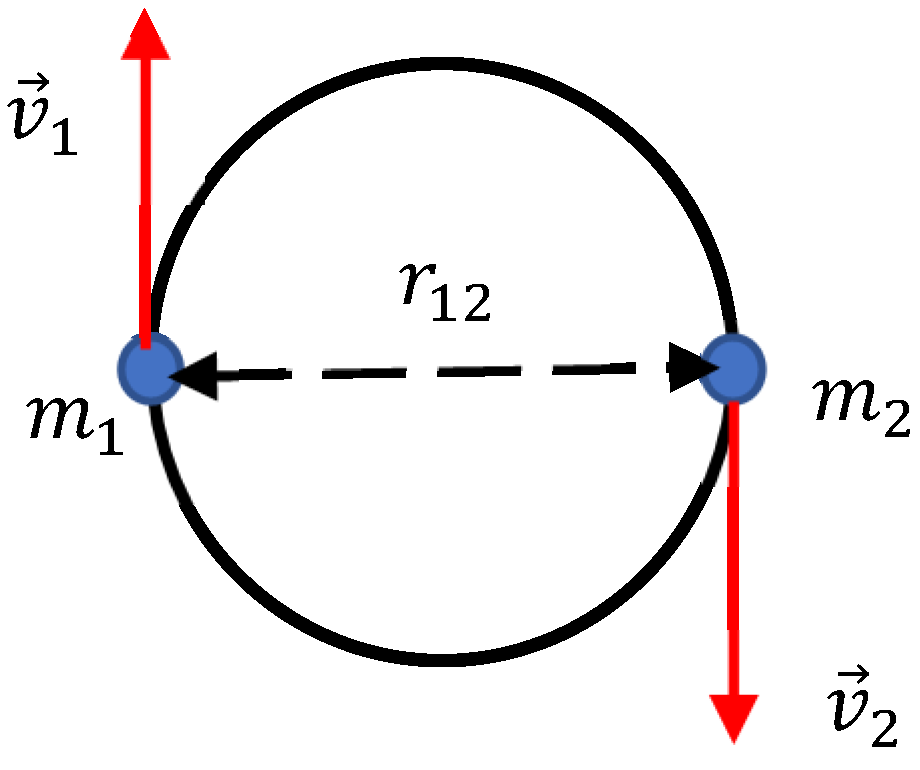
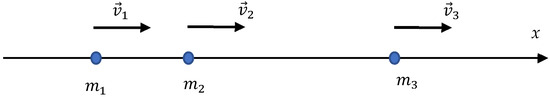
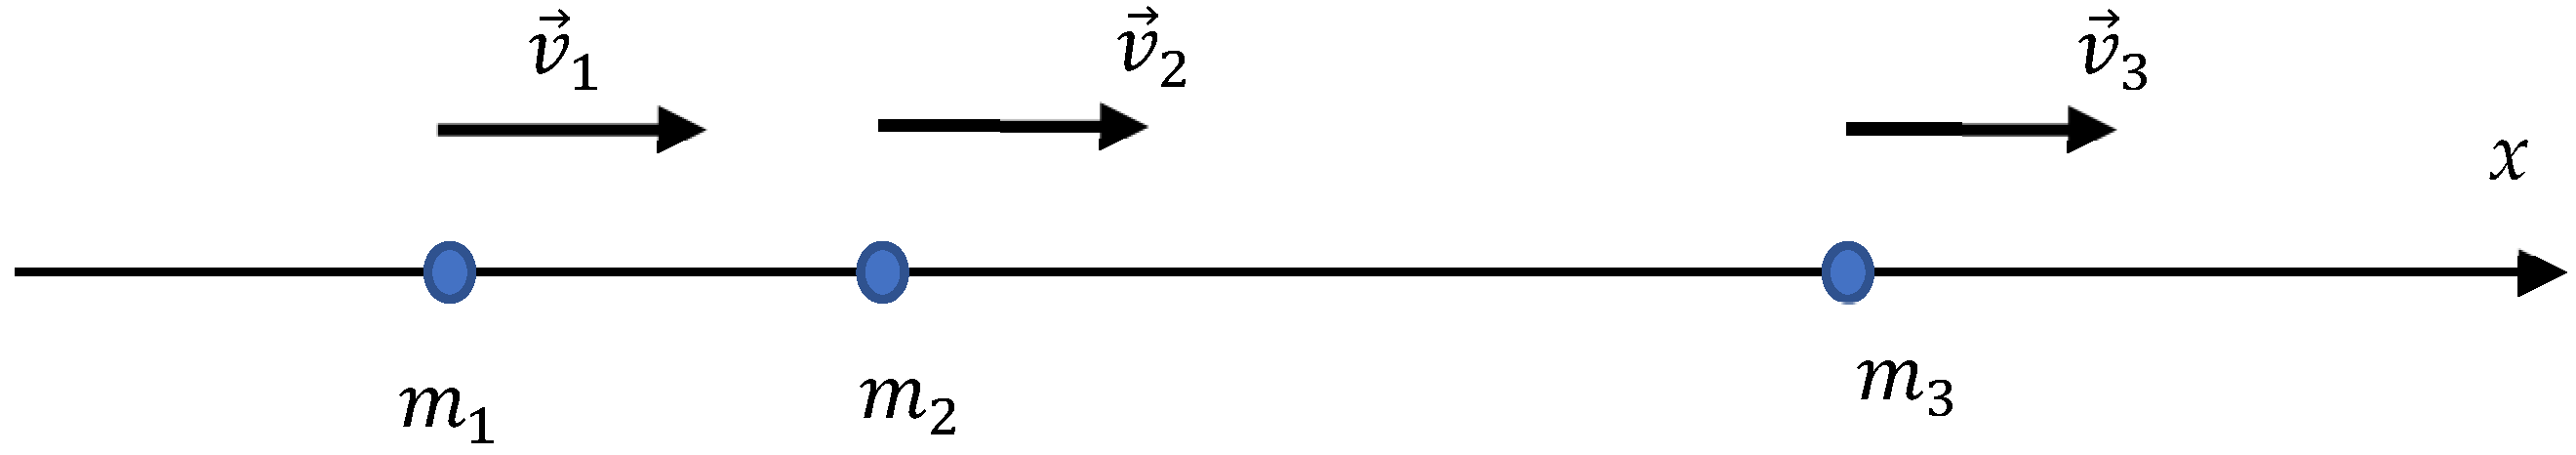
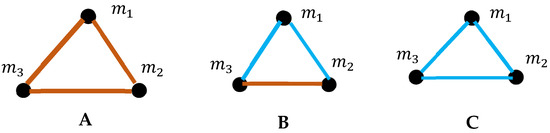
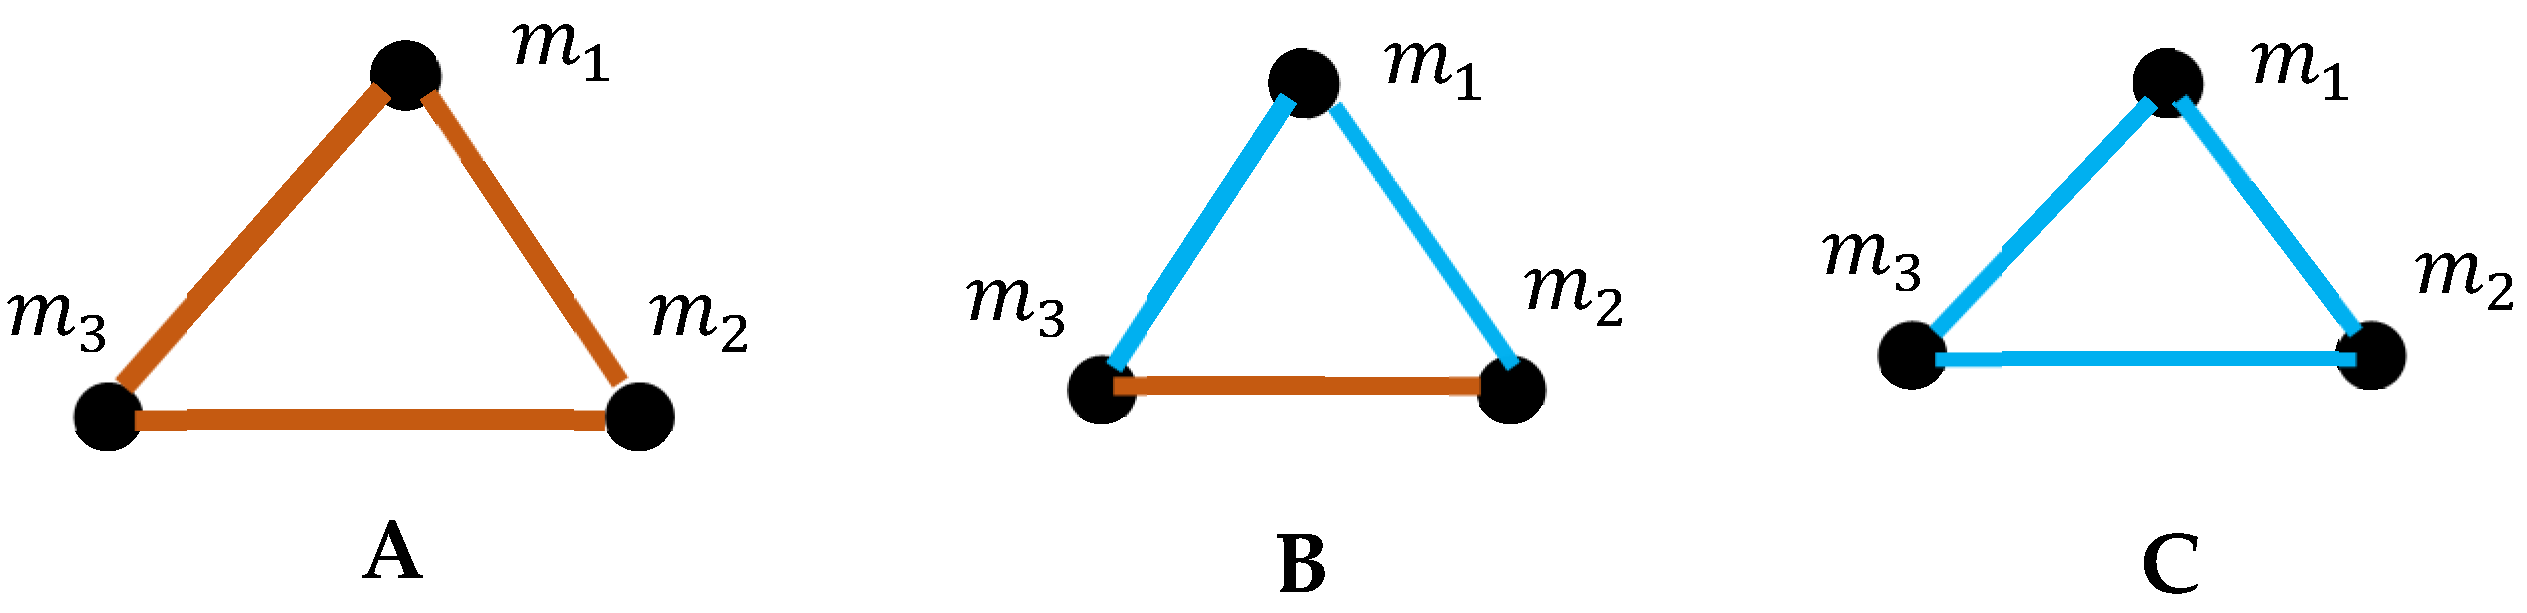
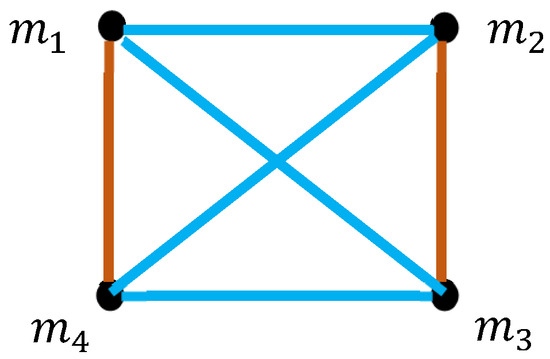
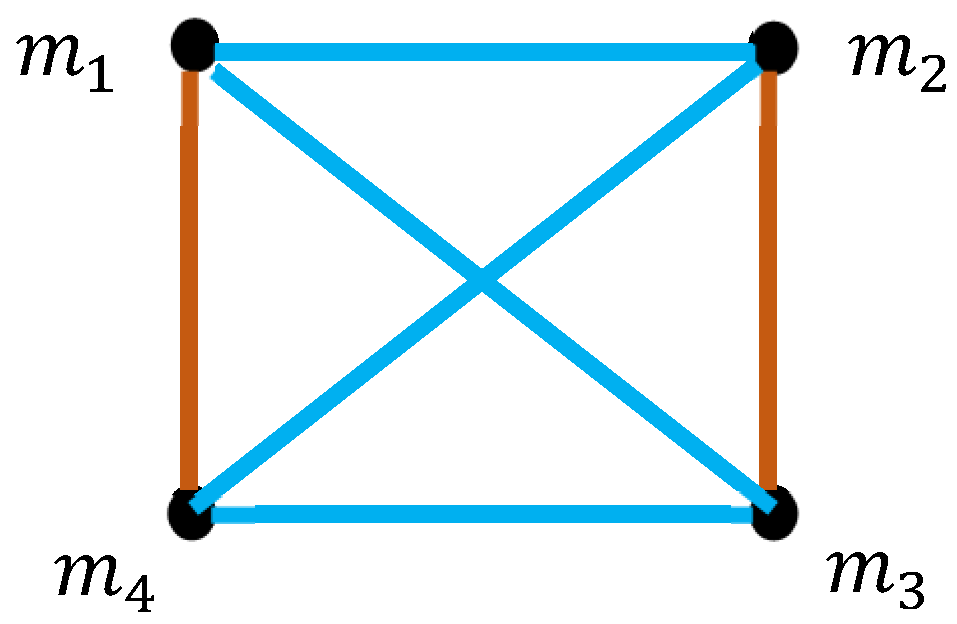
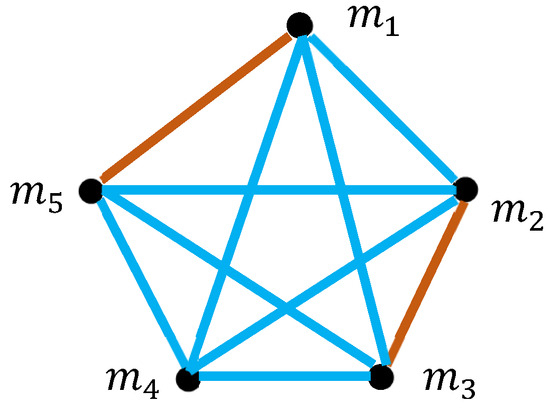
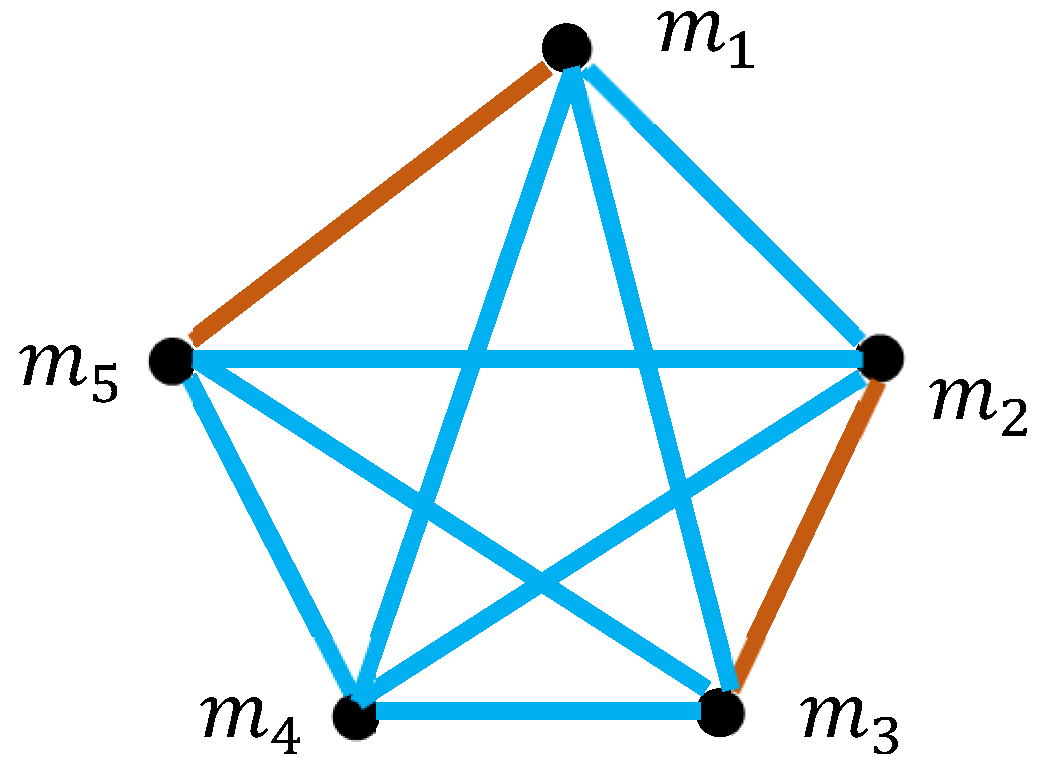
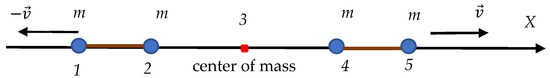
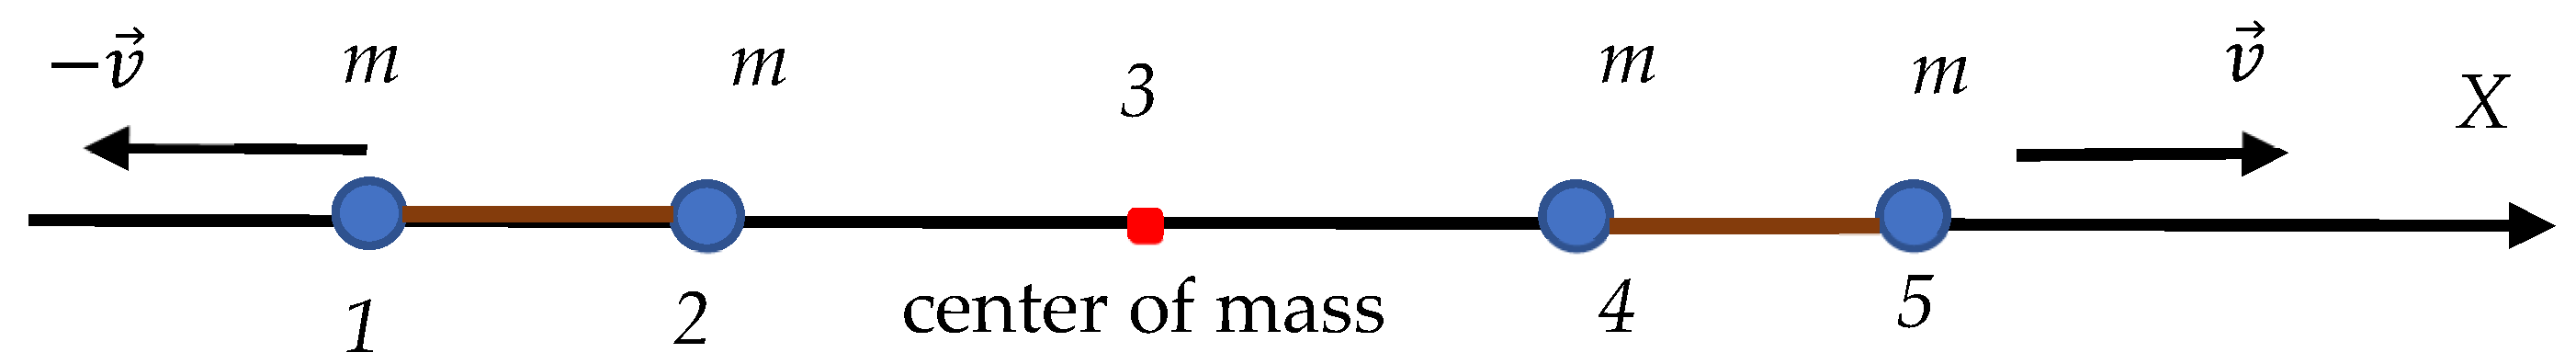
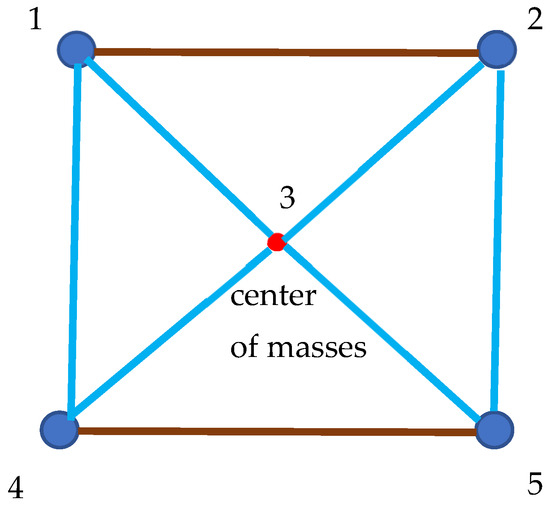
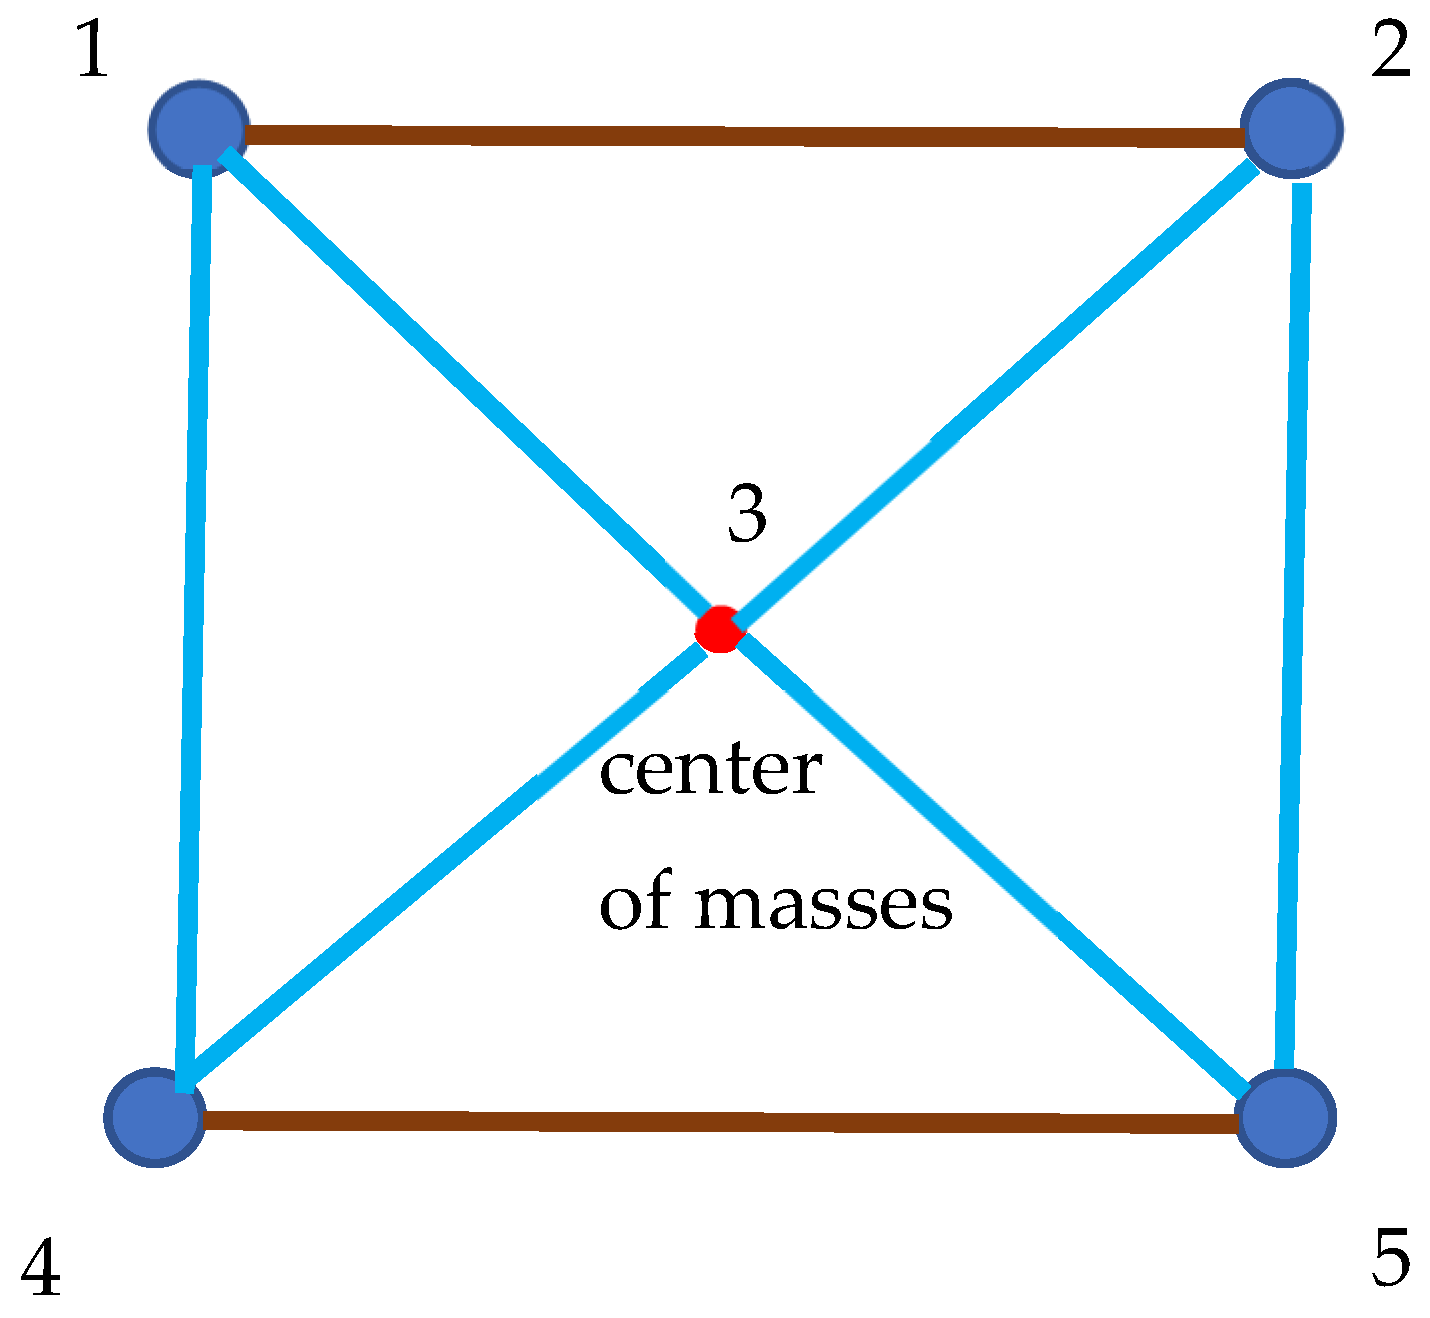
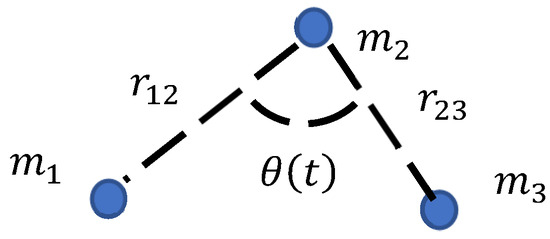
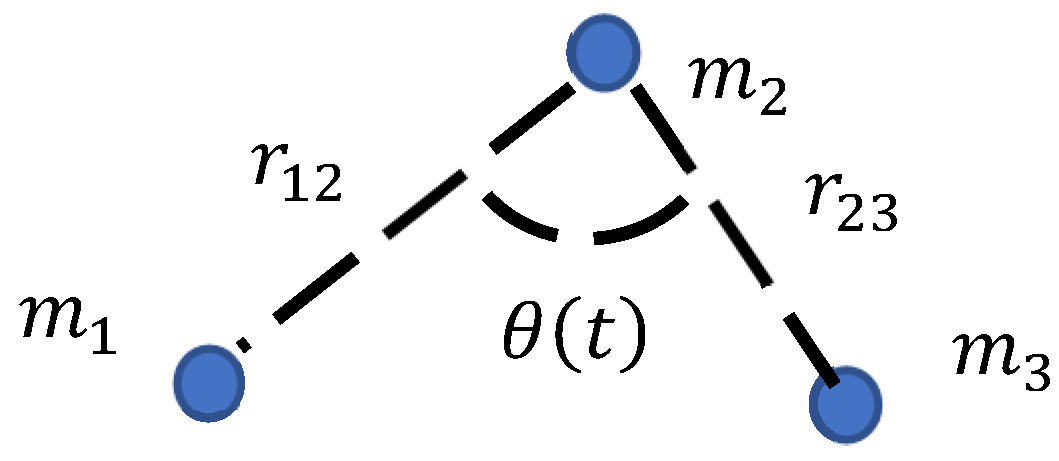
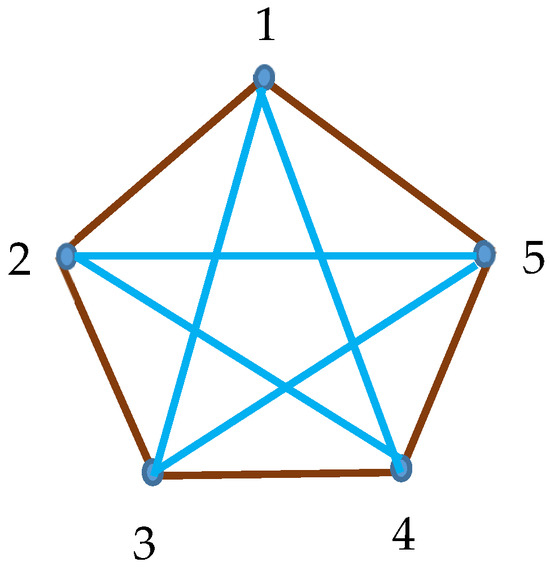
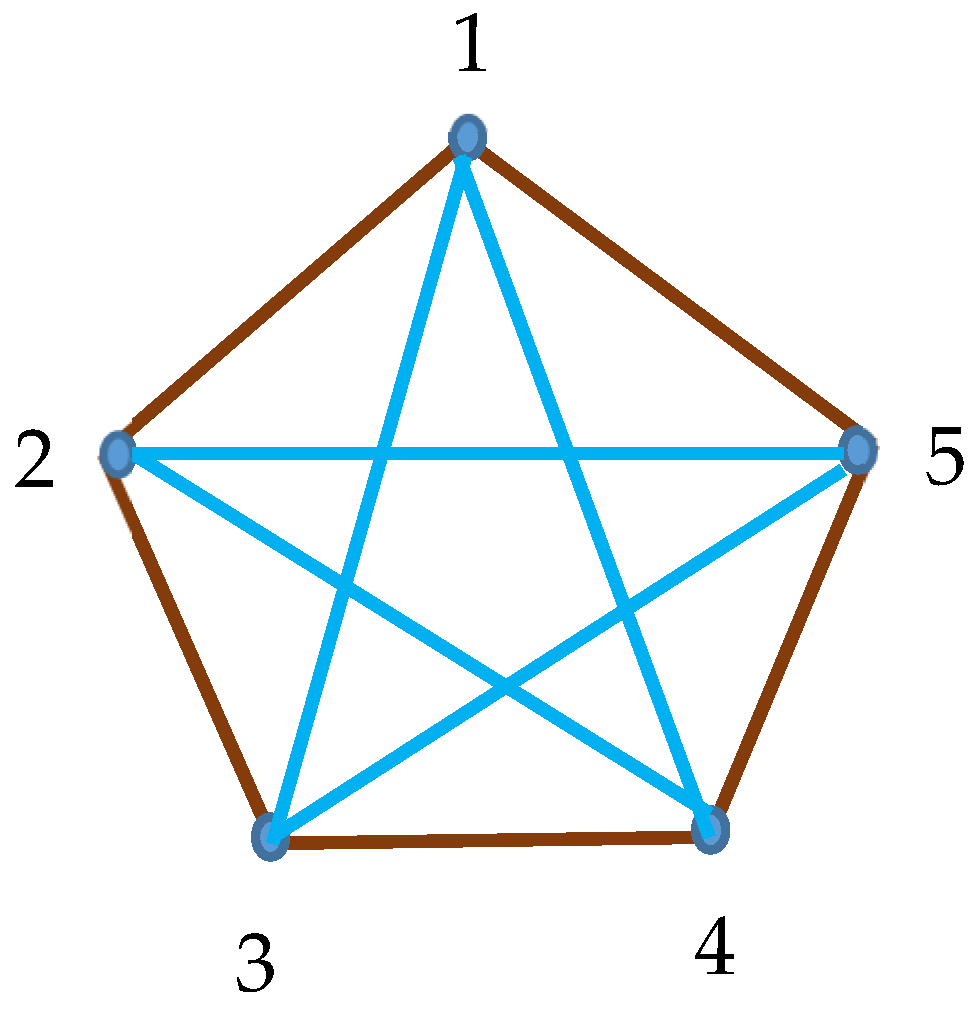
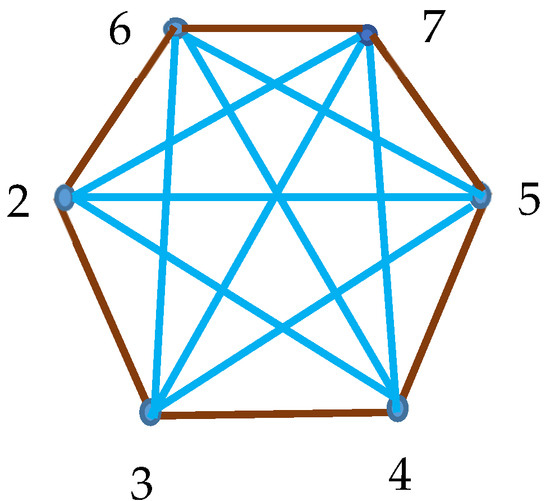
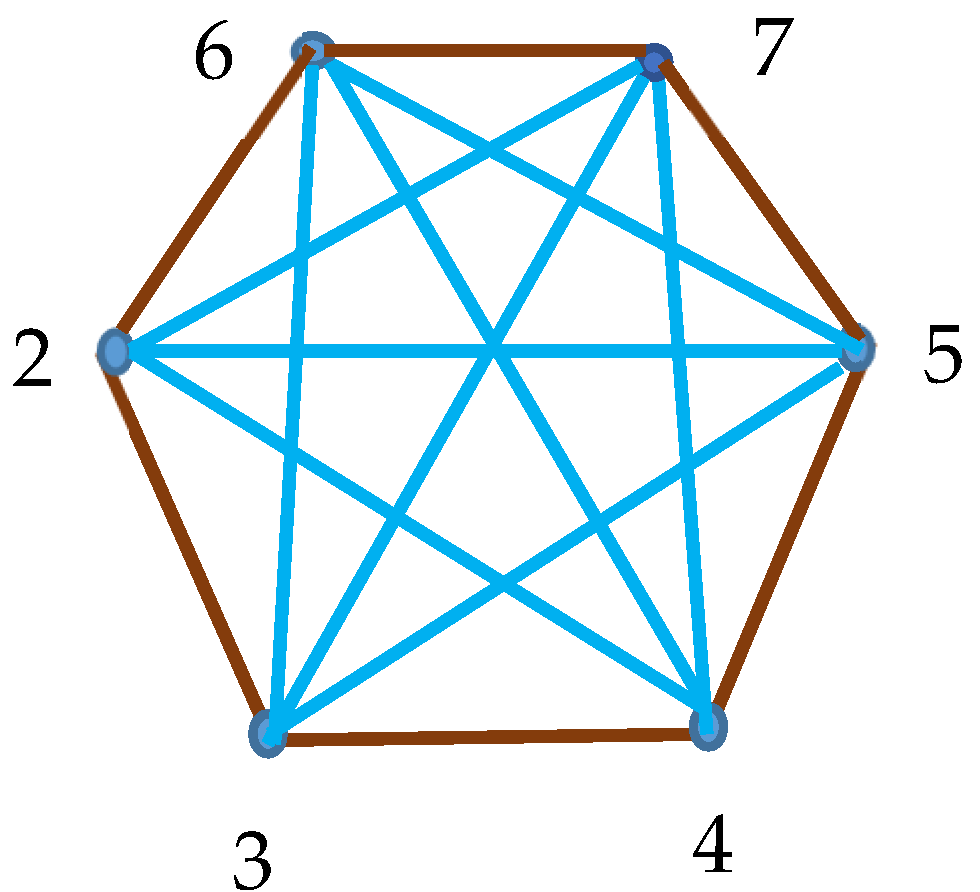
Disclaimer/Publisher’s Note: The statements, opinions and data contained in all publications are solely those of the individual author(s) and contributor(s) and not of MDPI and/or the editor(s). MDPI and/or the editor(s) disclaim responsibility for any injury to people or property resulting from any ideas, methods, instructions or products referred to in the content. |
© 2026 by the author. Licensee MDPI, Basel, Switzerland. This article is an open access article distributed under the terms and conditions of the Creative Commons Attribution (CC BY) license.