


Abstract
Liquid storage tanks are widely used in sectors such as water treatment, oil and gas, food processing, and chemical manufacturing. Knowing the exact amount of liquid in a tank is essential for ensuring safety, preventing spills, and optimizing process control; therefore, the liquid level in a tank must be maintained at a precise reference point. This is where liquid level control for tanks becomes crucial and constitutes a fundamental problem in the industrial sector due to nonlinearities, multivariable coupling, and stochastic disturbances. Given the drawbacks of available control methods, such as classical Model Predictive Control (MPC), which are highly dependent on model accuracy and struggle to reject complex stochastic noise, predicting random disturbances represents a major technological challenge. A new approach is proposed to specifically address the problem and challenge of the four-tank system, where water levels in two lower tanks must be controlled by two pumps, often with varying delays and significant parameter disturbances. To establish a relationship between expected performance and MPC parameters, this approach uses a novel hybrid nonlinear MPC, Extended State Observer, and Physics-Informed Neural State Estimation (NMPC-ESO-PINSE) architecture. A Physics-Informed Neural State Estimation (PINSE) layer, chosen for its learning capacity, is designed to filter sensor noise by applying Bernoulli’s physical laws, while an Extended State Observer (ESO) is integrated to capture and compensate for unmodeled uncertainties in the process. Finally, a proposed hybrid (NMPC-ESO-PINSE) strategy leverages these clean, physically consistent state estimations to solve a non-convex optimization problem via Sequential Quadratic Programming (SQP), computing optimal pump voltages. Extensive numerical simulations demonstrate the superior resilience of this decoupled framework against parametric drifts and continuous noise sequences, yielding a
reduction in global Root Mean Square Error (RMSE) compared to standard NMPC, accelerating the closed-loop settling time to , and restricting transient overshoot to just .
1. Introduction
Managing liquids such as water, as well as gas, oil and chemicals, is a critical aspect of various sectors, necessitating advanced systems for efficient storage, conservation, and distribution. There are many ways to store liquids in a distribution system and the control system is the key element to ensure that everything is done properly. Note that environmental processes present many difficult control problems due to nonlinear dynamic behavior, uncertain and time-varying parameters, constraints on operated variables, interaction between operated and controlled variables, unmeasured and constant disturbances, dead times on inputs and measurements, etc. [1,2,3].
Liquid level tanks are used in many industrial and environmental fields. Controlling the liquid levels in tank systems is ubiquitous in industry. NMPC is technique that has the power to optimize processes with constraints, manage multivariable, coupled and nonlinear systems, feature optimal control and incorporate future references when feasible [4,5,6]. It has gained significant popularity due to its numerous applications in both academia and industry. MPC belongs to a class of optimal control that involves solving an optimization problem at each time step. It uses a process model to calculate future expected outputs and choosing the best decision in terms of a certain cost while respecting the constraints. These expected outputs are then used to calculate a series of control inputs that are sent to the system to optimize the future behavior of the plant [7,8,9]. Often all industrial applications impose constraints. How to manipulate them in the configuration of the control system is an important question. The important advantage of MPC is its ability to cope with strict constraints on commands, outputs and states. Imposing constraints on the control system or ignoring them can cause performance degradation or instability, especially for unstable systems [10,11]. However, the performance of NMPC is heavily dependent on the accuracy of state estimation. In industrial environments, sensors are frequently corrupted by high-variance stochastic noise, and process dynamics are affected by unmodeled disturbances such as leaks or pressure fluctuations [12,13].
While the Kalman filter (KF) has been the gold standard for state estimation, it assumes that noise (measurement and process) follows a normal distribution. However, in a factory, noise is often “impulsive” (taking the form of sudden pressure spikes) or related to non-stochastic sensor errors [14,15]. For fluids, the Extended Kalman filter (EKF) is often used. It uses a Taylor series to linearize the system. The approximation error grows significantly and the filter diverges if the nonlinearity is substantial (for example, a sudden change to turbulent flow) [16,17]. A fixed internal model is used by the KF. When a leak occurs, the KF attempts to “smooth” the inaccuracy by interpreting it as measurement noise rather than recognizing that the system’s physics has changed [18,19]. Despite the success of standalone schemes in the literature including advanced distributed multiparametric setups or localized observer couplings [20] a significant gap remains. Traditional hybrid MPC-ESO architectures often suffer from a “noise-tracking” phenomenon where the observer overcompensates for high-frequency stochastic fluctuations, leading to aggressive actuator chattering. Conversely, standalone physics-informed models, while ensuring physical consistency, lack the real-time adaptive disturbance rejection needed to handle unexpected non-stochastic load changes like sudden leaks. To overcome these issues, this study proposes a novel triple-layer architecture known as NMPC-ESO-PINSE.
The PINSE incorporates physical laws, such as Bernoulli’s equation for fluids, directly into a neural network’s loss function to improve state estimation [21,22,23]. By avoiding the linearity constraints and Gaussian assumptions of the conventional Kalman filter in industrial settings, this method acts as a smart filter that offers resilience to stochastic noise. PINSE provides stable and clean data for NMPC by guaranteeing physically consistent trajectories [24,25,26].
The ESO acts as a robust control mechanism by estimating and compensating in real time for uncertainties and disturbances (modeled as an extended state) in fluid systems [27,28,29,30]. By comparing the actual output to the predictions, the ESO enables direct compensation, acting as a superior “deviation detector” compared to classical methods, notably by simplifying modeling and increasing responsiveness to process changes [31,32,33,34].
The NMPC serves as the “brain” to make decisions in this three-layer architecture. Its job is to use data that has been cleaned up by the two layers before it to determine the best control strategy (such as valve opening or pump speed). The caliber of the NMPC’s inputs determines its success. The NMPC is given a new dimension by employing “cleaned” states [35]. The PINSE gives the NMPC a stochastic noise-free initial state [36]. With PINSE, the NMPC begins its calculation on a physically consistent basis (Bernoulli’s law), ensuring a smooth and stable control trajectory. Without PINSE, the NMPC would react to noise, causing micro-oscillations in the actuators (valve wear) [37,38]. The ESO sends an estimate of the “total perturbation” (leaks, model errors) to the NMPC in order to account for unanticipated events [39,40].
The core novelty of this work lies in the synergistic integration of ESO and PINSE within a NMPC loop. The major innovation of this work lies in the synergistic integration of the ESO and PINSE within a Predictive Control Loop. This new hybrid architecture is proposed to specifically address the problem and challenge posed by the four-reservoir system, where the water levels in the two lower reservoirs must be controlled by two pumps, often with variable delays and significant parametric perturbations. It is designed to overcome the dual challenge of stochastic noise and unmodeled nonlinear perturbations. This triple-layer architecture establishes a robust feedback loop. The PINSE module focuses on reconstructing the nonlinear state by filtering stochastic noise through physical constraints, while the ESO concurrently identifies the lumped disturbances. This bifurcated estimation strategy provides the MPC with a comprehensive and high-fidelity representation of the system dynamics, enabling tracking accuracy performance under uncertain conditions.
The remainder of this paper is structured as follows: Section 2 outlines the process description and nonlinear modeling of the quadruple-tank system. Section 3 details the development of the Nonlinear Model Predictive Control (NMPC) strategy. Section 4 presents the formulation of the Extended State Observer (ESO) for lumped disturbance estimation. Section 5 discusses the Physics-Informed Neural State Estimation (PINSE) framework for nonlinear state reconstruction. The proposed integrated hybrid NMPC-ESO-PINSE architecture is demonstrated in Section 6. Section 7 delivers the comprehensive simulation results and comparative performance discussions. Finally, Section 8 offers concluding remarks and outlines future research directions.
2. Process Description and Modeling
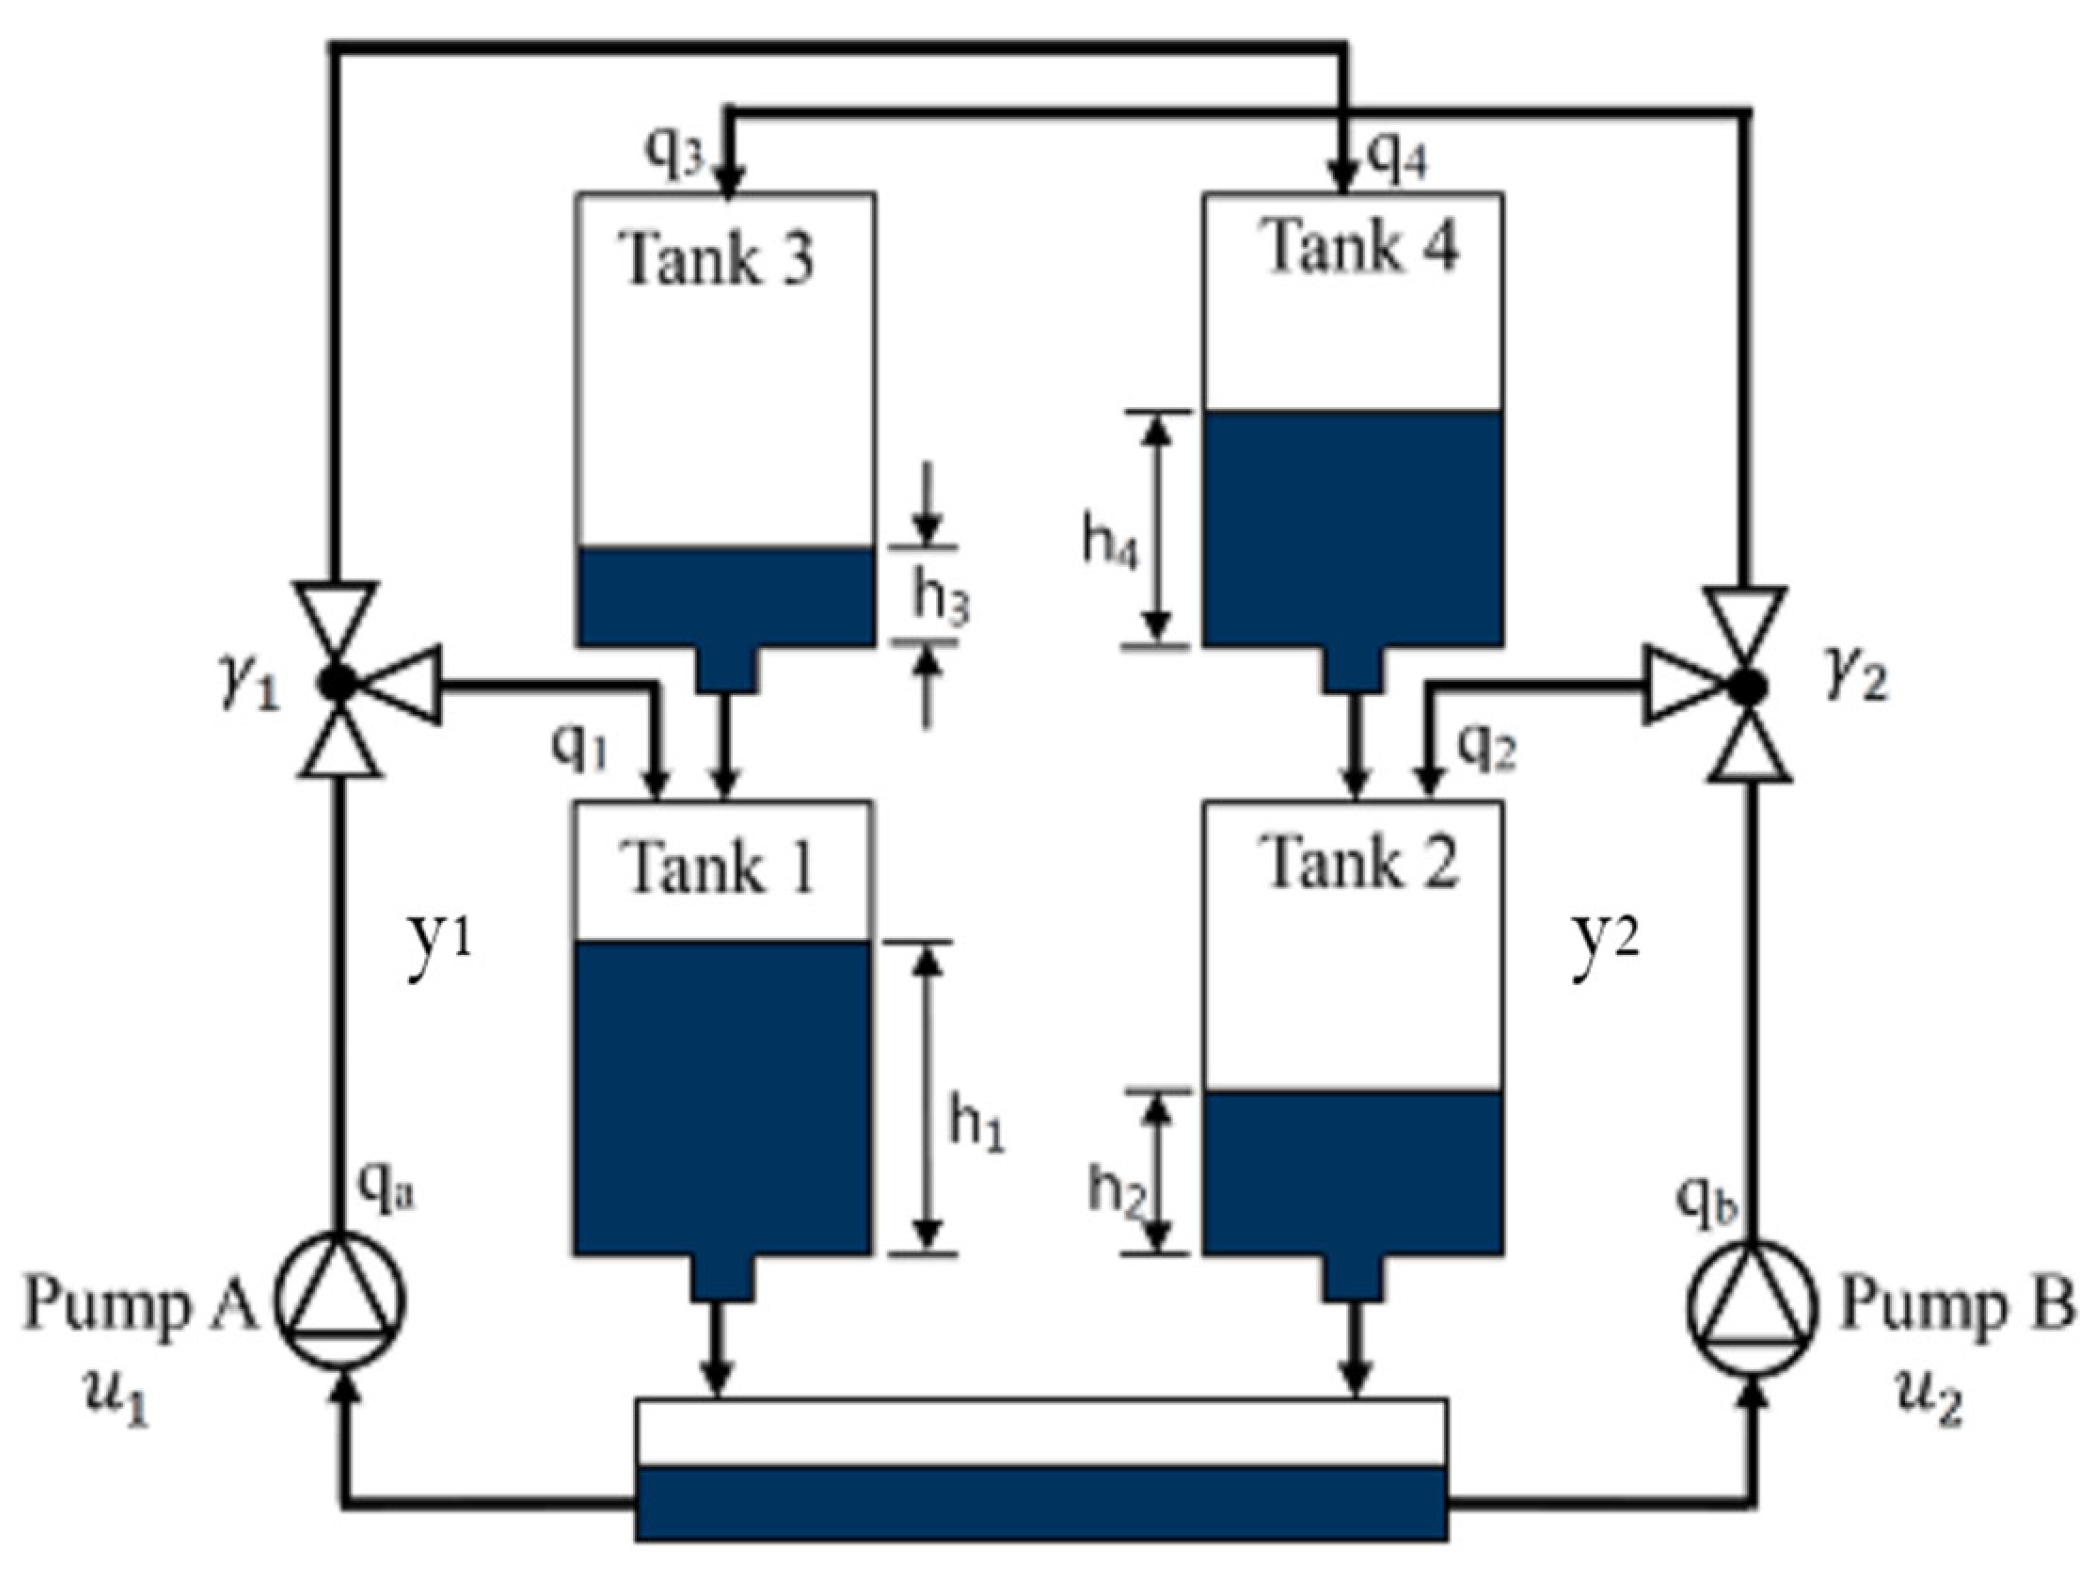
The proposed hybrid NMPC-ESO-PINSE architecture is implemented to regulate the liquid levels of a four-tank system configured in a non-minimum phase mode given in Figure 1. This configuration is specifically chosen for its control complexity, which is further exacerbated by stochastic uncertainties and load disturbances.
Figure 1.
Schematic diagram of the four-tank system.
The nonlinear dynamics of the four-tank system are governed by the following mass balance equations:
where
: Surface of cross section area of the tank i;
: Surface of cross section of the exit hole i;
: Level of water in the tank i;
: Voltage of the pump i;
: Constant of valve i;
: Constant of pump i;
g: Acceleration of gravity.
3. Nonlinear Model Predictive Control Strategy
Model Predictive Control (MPC) is an optimal control strategy in which computed actions are calculated to minimize a cost function for a dynamic system with constraints over a finite and decreasing horizon [41,42]. At each sampling step, an MPC controller receives or estimates the present state of the process [43]. It then computes a sequence of control actions that minimizes an objective function by solving an optimization problem under constraints. According to the receding horizon principle, the controller applies only the first determined control action to the plant, ignoring subsequent ones, and the process is repeated at the next time step [44,45].
In this framework, the internal model used to examine the behavior of the process can be linear or nonlinear [46,47]. While traditional MPC designs often rely on linearized formulations to reduce computational complexity, such approximations introduce significant mismatch when applied to highly nonlinear systems. Therefore, to fully capture the hydraulic dynamics of four-tank system across its entire operating range and handle its non-minimum phase characteristics, a nonlinear MPC (NMPC) framework is explicitly developed and implemented in this study.
3.1. Mathematical Formulation of the Optimization Problem
The continuous-time behavior of the four-tank system is governed by a set of coupled nonlinear ordinary differential equations, compactly formulated as follows:
Unlike standard linear MPC, which relies on Quadratic Programming (QP) and functions like “quadprog”, which evaluates state transitions via analytical algebraic state-space matrices (A, B). The NMPC optimizer predicts the future state by executing a continuous-to-discrete numerical integration of the raw continuous-time vector field . To guarantee strict structural compliance with Bernoulli’s conservation laws while ensuring computational efficiency within the control loop, an explicit forward Euler integration scheme is embedded within the prediction pipeline by integrating the dynamic disturbance vector calculated by the tracking layer. The a priori state prediction projection for the next sampling step is evaluated via:
where denotes the current synchronized state estimation vector, represents the optimal control vector, represents the estimated augmented total disturbance vector and is the sampling period. The function encompasses the full nonlinear differential equations of the four-tank system, specifically accounting for the Bernoulli-based square-root terms Equations (1)–(4).
At each discrete sampling interval , corresponding to the continuous time (where is the sampling period), the controller solves a finite constrained open-loop optimization problem. To ensure real-time feasibility and minimize the computational burden, a single-step ahead prediction horizon is implemented. The mathematical sufficiency of the single-step prediction horizon under non-minimum phase constraints is structurally guaranteed by the active disturbance rejection loop. The nonlinear multi-variable plant field is defined where d(t) encompasses the fluid cross-couplings and parametric uncertainties. Because the high-bandwidth augmented ESO tracks and cancels these unmodeled interactions at each sampling instant, the active compensation law is embedded directly within the optimization loop. This feedback dissipation mechanism uncouples the localized transient projection, altering the predictive optimization manifold. Consequently, the unstable RHP zero transmission delays are dynamically mitigated by the estimation layer at step k, making a single-step-ahead horizon theoretically sufficient to secure closed-loop stability and recursive feasibility without requiring heavy multi-step prediction matrices.
The optimization objective is formulated as a constrained Nonlinear Programming (NLP) problem, defined mathematically as follows:
subject to the quadratic tracking and control effort cost function:
where the specific terms are defined as follows:
is the predicted state vector at step , computed based on the state information available at step .
represents the invariant reference target setpoint vector.
defines the control input change vector.
and denote the positive-definite symmetric weighting matrices calibrated to penalize tracking deviations and aggressive actuator chattering, respectively.
3.2. Operational Hard Constraints and Solver Strategy
The optimization problem is subject to the following physical constraints:
where and reflect the strict saturation voltage thresholds of the physical pumps, preventing actuator windup. The output state bounds and correspond to the physical floor and overflow limits of the hydraulic tanks.
4. Extended State Observer (ESO)
In the context of the nonlinear four-tank system, the Extended State Observer (ESO) serves as the backbone for disturbance rejection and state reconstruction. The fundamental challenge in controlling hydraulic systems lies in the presence of unmodeled dynamics, such as valve friction, leakage, and stochastic fluctuations in pump pressure [48,49]. Unlike a traditional linear observer, the proposed framework treats these uncertainties as a lumped “total disturbance” vector integrated directly within the plant’s nonlinear manifold. The structural integration of localized observers or switching estimation topologies within predictive loops has proven crucial for stabilizing highly coupled hydraulic manifolds [50].
To track state trajectories and compensate for unmodeled dynamics without computational expansion, the observer is formulated as a discrete-time predictor-corrector Extended State Observer (ESO). The plant state space is explicitly augmented by defining a four-dimensional total disturbance vector . The augmented discrete-time state vector is thus formalized as .
Following the recursive predictor-corrector mechanism implemented in the simulation routine, the state update and disturbance compensation law is defined as follows:
where the specific architectural parameters and gains match the control algorithm execution:
is the corrected state estimation vector at time step .
represents the a priori state prediction delivered by the continuous nonlinear plant model dynamics.
represents the estimated augmented total disturbance vector.
and denote the parameterized proportional and integral observer tracking feedback gains, calibrated to decouple measurement fluctuations from physical plant variations.
Once the correction step is completed, the a priori state transition projection for the next sampling step is predicted via
The complete coupled error tracking dynamics of the augmented predictor-corrector ESO are governed by a non-homogeneous time-varying discrete system. By applying a first-order Taylor expansion around the estimated hydraulic state trajectory, the continuous-time plant mismatch is linearized via the localized Jacobian matrix . Defining the state error as and the disturbance observation error as , the augmented error state vector evolves according to:
where represents the time-varying Schur stable error transition matrix and is the norm-bounded vector encapsulating the stochastic measurement noise and the non-stochastic disturbance rate of change. With the parameterized tuning gains and , the eigenvalues of the unperturbed transition matrix lie strictly within the unit circle on the z-domain, ensuring that the nominal unperturbed error dynamics are exponentially stable. Under continuous stochastic noise fluctuations and load variations , the full estimation error is mathematically proven to be Uniformly Ultimately Bounded (UUB), converging asymptotically into a compact residual ball around the origin.
5. Physics-Informed State Estimation (PINSE) for Nonlinear Modeling
Unlike a standard neural network that acts as a black-box regressor, the PINSE is designed as a dynamic observer. It maps the historical inputs and noisy outputs to the true state vector [51,52]. The PINSE architecture incorporates a state-space constraint within its hidden layers. The transition between estimated states is constrained by:
where
: is the current estimated state vector.
: is the control effort (voltage) applied to the pumps.
: represents the Bernoulli-based nonlinear dynamics of the system.
To ensure the model adheres to hydraulic principles, a physics-based loss function is used during the training phase. This loss incorporates the Bernoulli-based nonlinear dynamics as a structural regularizer:
where
: Represents the weights and biases of the neural network to be optimized.
: Weighting coefficient for the nominal simulation data fidelity term.
: Weighting coefficient for the physics conservation law term.
: Data Fidelity Term Minimizes the error between the predicted states and the noise-free simulation ground truth:
: The ideal noise-free reference trajectory.
: Physics residual penalizes violations of the fundamental conservation laws by computing the residual of the governing differential equations:
The PINSE architecture employs a state-space transition model where the neural network learns the complex mappings, while the physics residual serves as a structural regularizer [53,54]. This dual-layered approach ensures that the state estimates delivered to the NMPC are not only noise-resilient but strictly adhere to the fundamental conservation laws of hydraulic systems [55,56,57].
To ensure full reproducibility, the implementation and training specifications of the Physics-Informed Neural State Estimation (PINSE) layer are structured as follows:
- Network Topology: A feedforward Multilayer Perceptron (MLP) architecture containing one input layer, three hidden layers with 32 neurons each configured with hyperbolic tangent activation functions, and one linear output layer.
- Data Split: A synthesized dataset of 8000 samples generated via pseudo-random binary sequence (PRBS) continuous simulations, split into 80% for training (6400 samples) and 20% for offline validation (1600 samples).
- Optimization Pipeline: Executed via the Adam optimizer with a fixed learning rate of 0.001, a mini-batch size of 64, and trained over 500 epochs to achieve weight convergence.
- Loss Weights: The multi-objective cost function regularization factors are parameterized at and , balancing data fidelity with Bernoulli’s physical conservation laws.
Note that this deep learning optimization process is performed strictly offline to guarantee the convergence of the structural parameters. The resulting optimized physical knowledge is embedded online within the active real-time control script via the unified discrete-time weightings (0.3 for measurements and 0.7 for physical priors), successfully ensuring high noise resilience without introducing online computational latency.
6. Proposed Hybrid NMPC-ESO-PINSE Architecture
Despite the success of separate ESO and PINN schemes, the existing literature lacks a unified framework that decouples stochastic filtering from active disturbance rejection. Traditional hybrid models often suffer from performance degradation when sensor noise is high, as the observer “tracks” the noise instead of the disturbance. The proposed NMPC-ESO-PINSE architecture bridges this gap by introducing a multilayer feedback loop where the PINSE ensures physical consistency while the ESO identifies structural anomalies, providing the NMPC with a high-fidelity and context-aware state estimate.
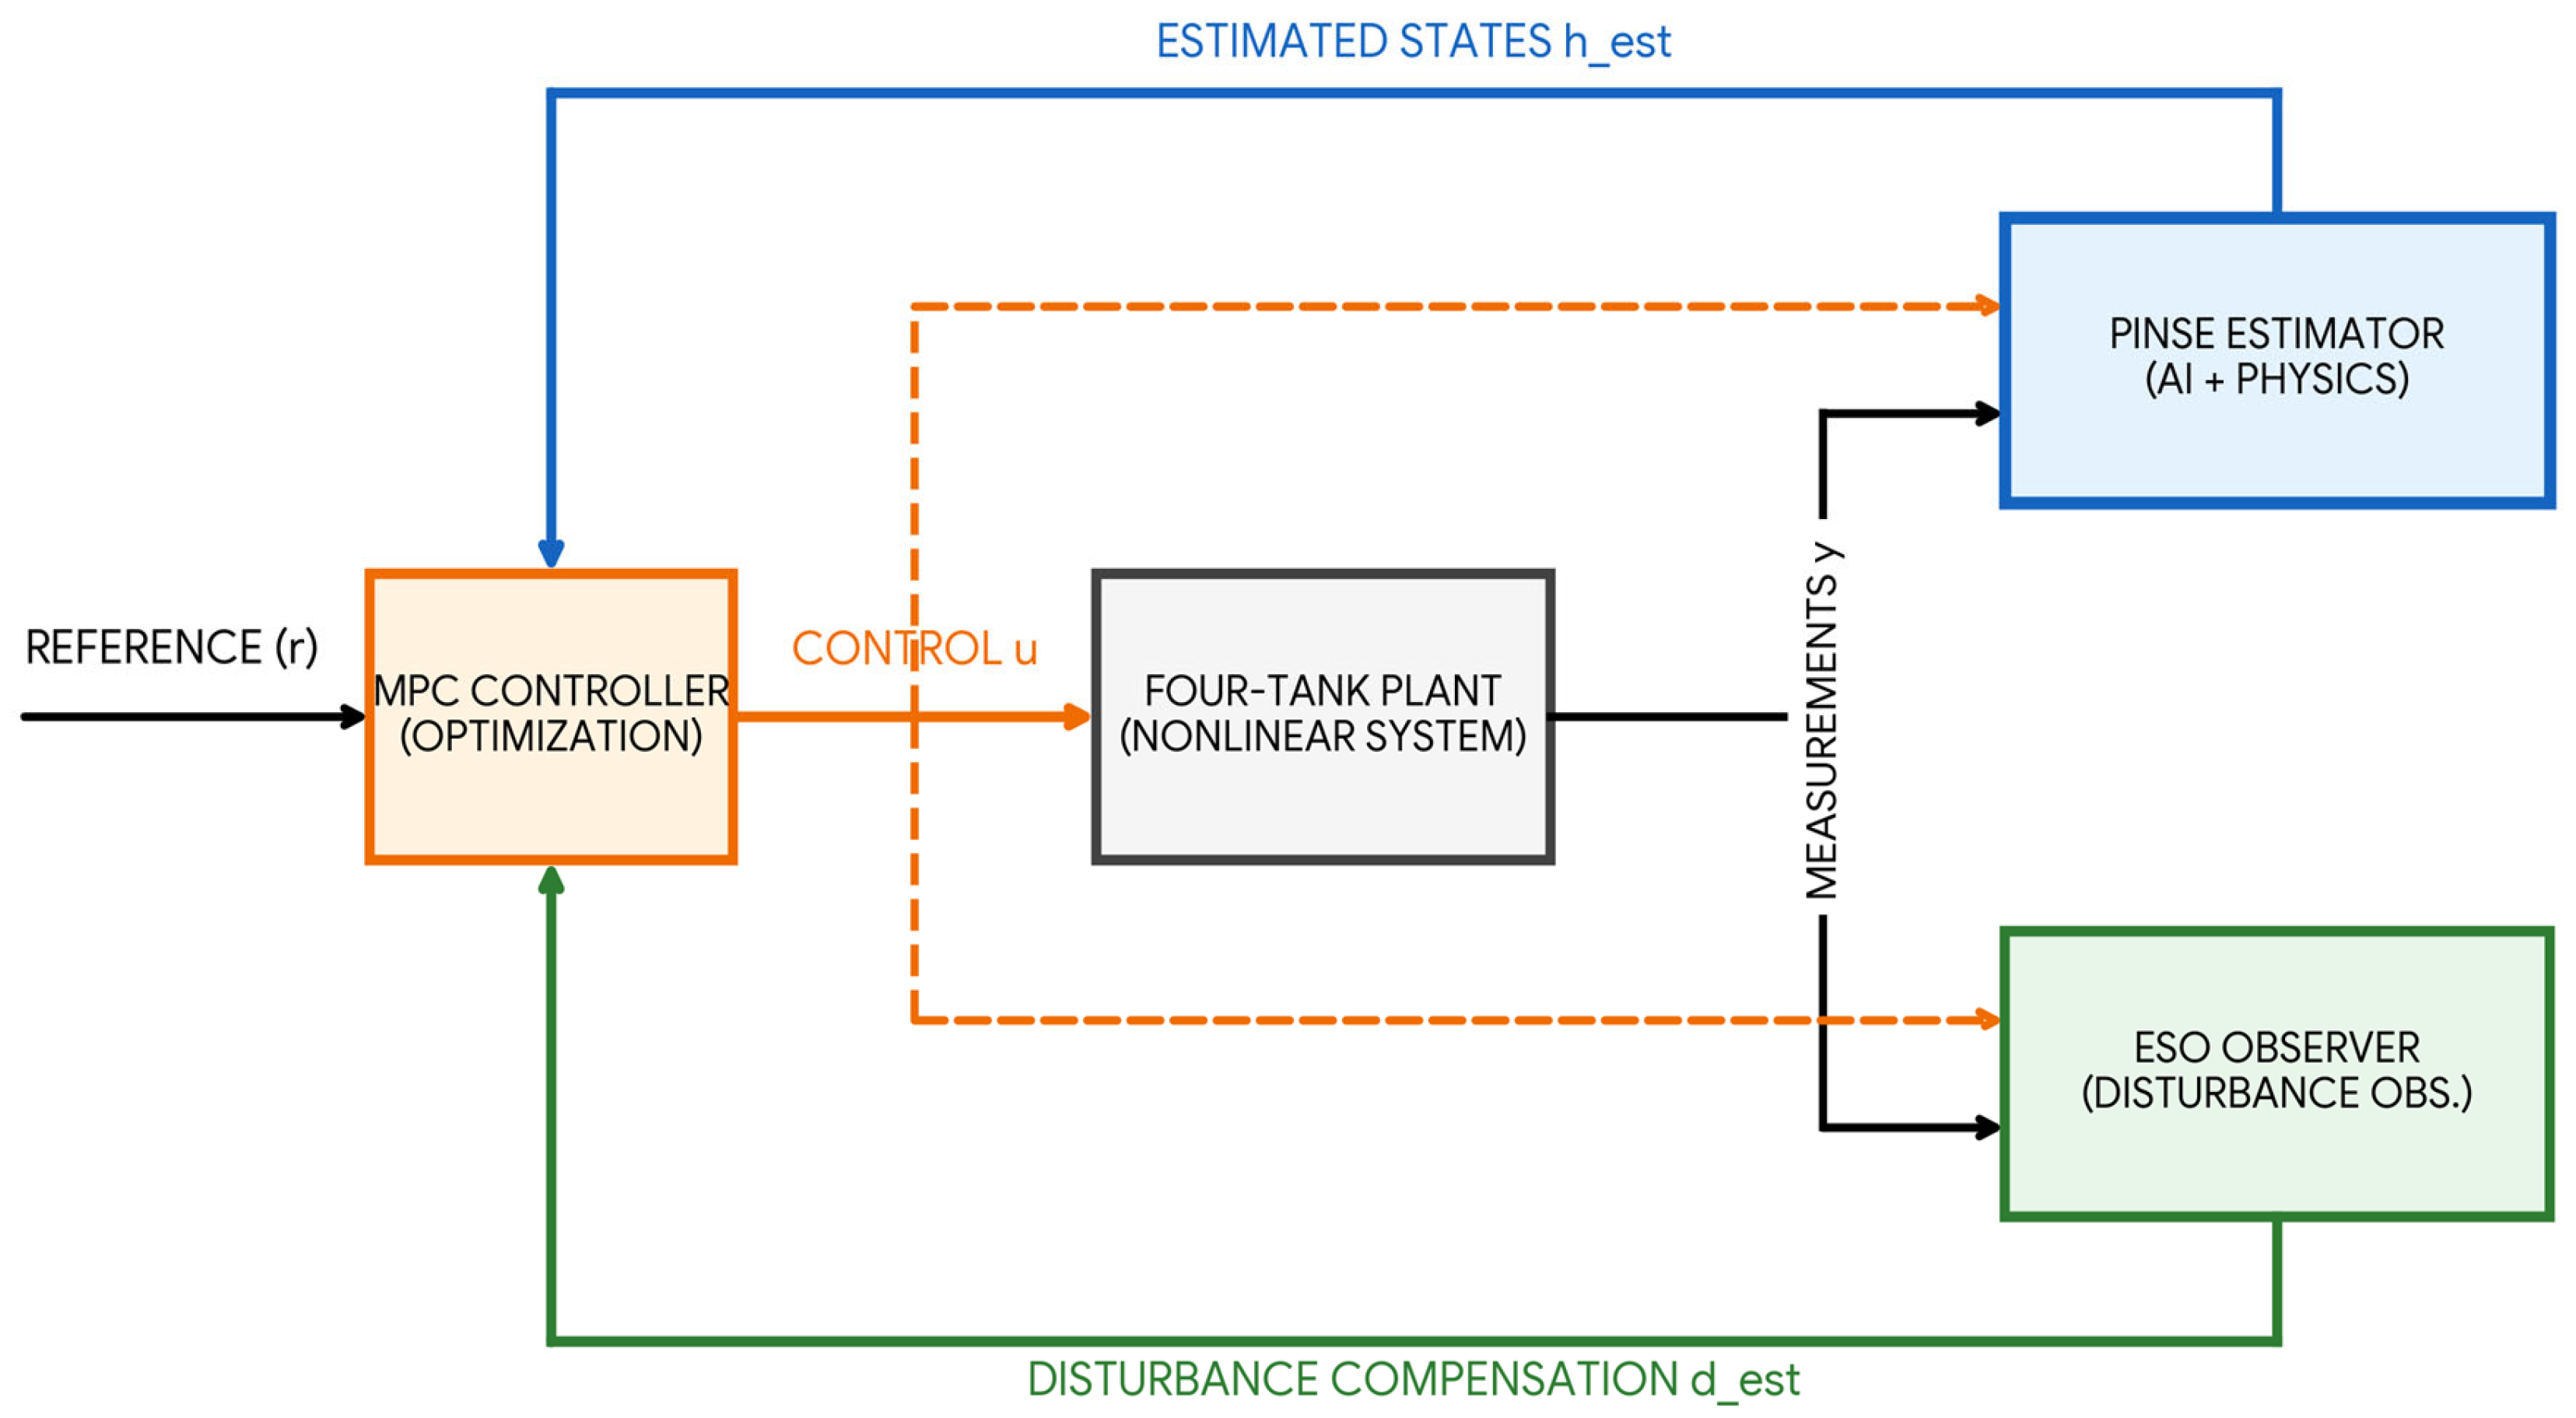
The overall control architecture proposed in this study is illustrated in Figure 2. The framework is structured as a triple-layer closed-loop system designed to decouple stochastic noise filtering from active disturbance rejection. The synergy between these modules is described as follows:
Figure 2.
Suggested hybrid NMPC-ESO-PINSE control architecture for the four-tank system.
The Physics-Informed Neural State Estimator (PINSE) serves as a “physical anchor”. By receiving the control input and the noisy measurements , it reconstructs the state vector through a Bernoulli-compliant manifold. Its primary role is to ensure that the states delivered to the controller are physically consistent and free from high-frequency stochastic noise.
Operating in parallel, the ESO identifies unmodeled dynamics and external disturbances (such as leaks or pressure drops). It generates a compensation signal that represents the “total disturbance”. By isolating these structural changes from the high-frequency noise already handled by the PINSE, the ESO avoids the common “noise-tracking” phenomenon, enhancing the stability of the observer.
The NMPC controller acts as the central decision-making unit. It integrates the “clean” estimated states and the disturbance compensation signal to solve a non-convex optimization problem via the SQP algorithm. This allows the controller to compute an optimal control effort that is robust to both measurement noise and unmodeled nonlinear perturbations, even within the challenging non-minimum phase region.
7. Simulation Results and Discussions
7.1. Simulation Results
To evaluate the effectiveness of the proposed NMPC-ESO-PINSE architecture, we performed simulations using MATLAB (version R2020a, MathWorks) environment. The system parameters , are based on the standard benchmark values for the non-minimum phase configuration as defined in Table 1, where the specific choice of and ensures a right half-plane zero, presenting a significant control challenge for the hybrid MPC-ESO-PINSE architecture.
Table 1.
Nominal parameters used for the nonlinear dynamical model.
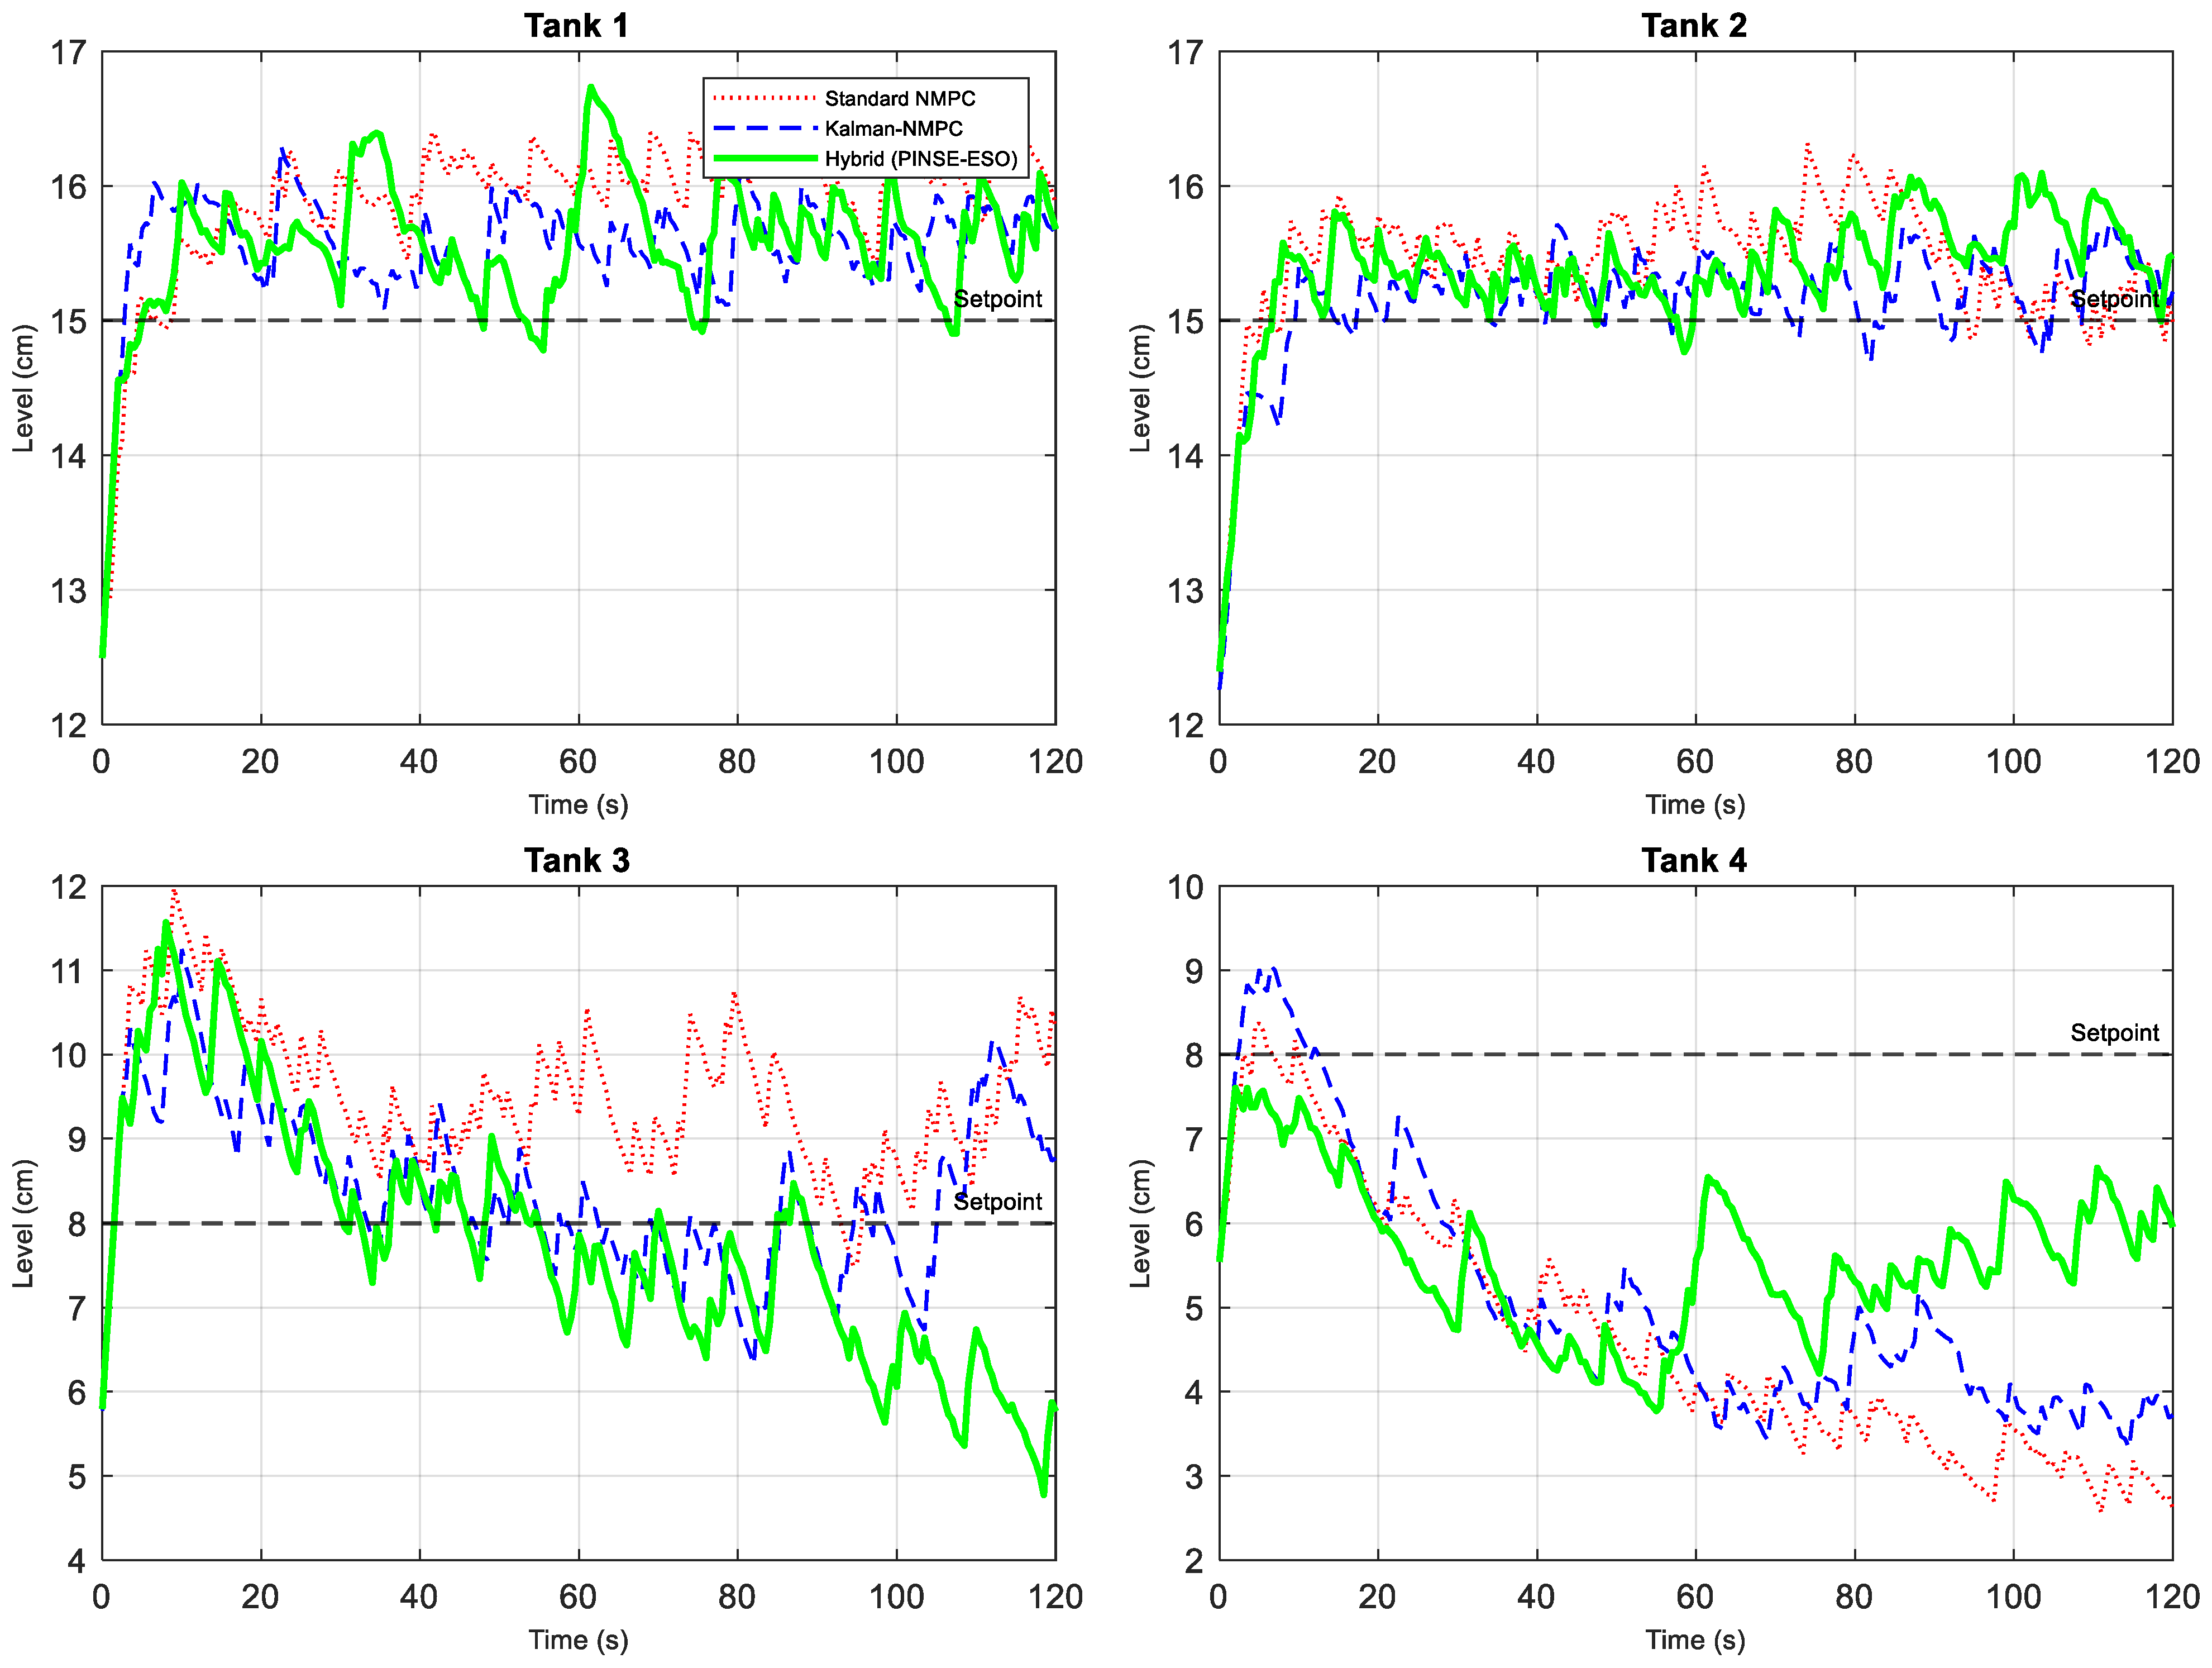
The dynamic response of the four-tank system, under three different control strategies, is illustrated in Figure 3. The objective was to maintain water levels at predefined set points (15 cm for tanks 1 and 2; 8 cm for tanks 3 and 4). To stress-test the robustness of each control strategy, the system was subjected to a continuous stochastic zero-mean Gaussian measurement noise with a standard deviation of , alongside random process disturbances modeled with a standard deviation of .
Figure 3.
Comparative analysis of liquid level tracking for the four-tank system under standard NMPC, Kalman-NMPC, and Hybrid NMPC-ESO-PINSE control strategies.
The dynamic closed-loop response of the four-tank system under the three benchmarked control strategies is illustrated in Figure 3.
The Standard NMPC approach exhibited highly oscillatory trajectories and severe chattering across all operating tanks. Lacking a robust estimation layer, the controller directly propagated high-frequency sensor noise into the optimization loop. This resulted in delayed settling times and poor tracking accuracy, particularly under the non-minimum phase constraints of the plant.
The integration of a standard Kalman-NMPC mitigated the sensor noise, yielding smoother state trajectories. However, because the standard Kalman filter relies on local approximations, its convergence rate remained sluggish, failing to efficiently reject unmodeled nonlinear dynamics and process fluctuations.
The proposed hybrid NMPC-ESO-PINSE architecture demonstrated enhanced tracking accuracy performance. By leveraging the physics-informed regularizer from the PINSE block and the active disturbance rejection capability of the ESO, the controller successfully mitigated the transient limitations of the unstable right half-plane (RHP) zero. The liquid levels converged rapidly to their target references with minimal transient overshoot and highly attenuated steady-state variance.
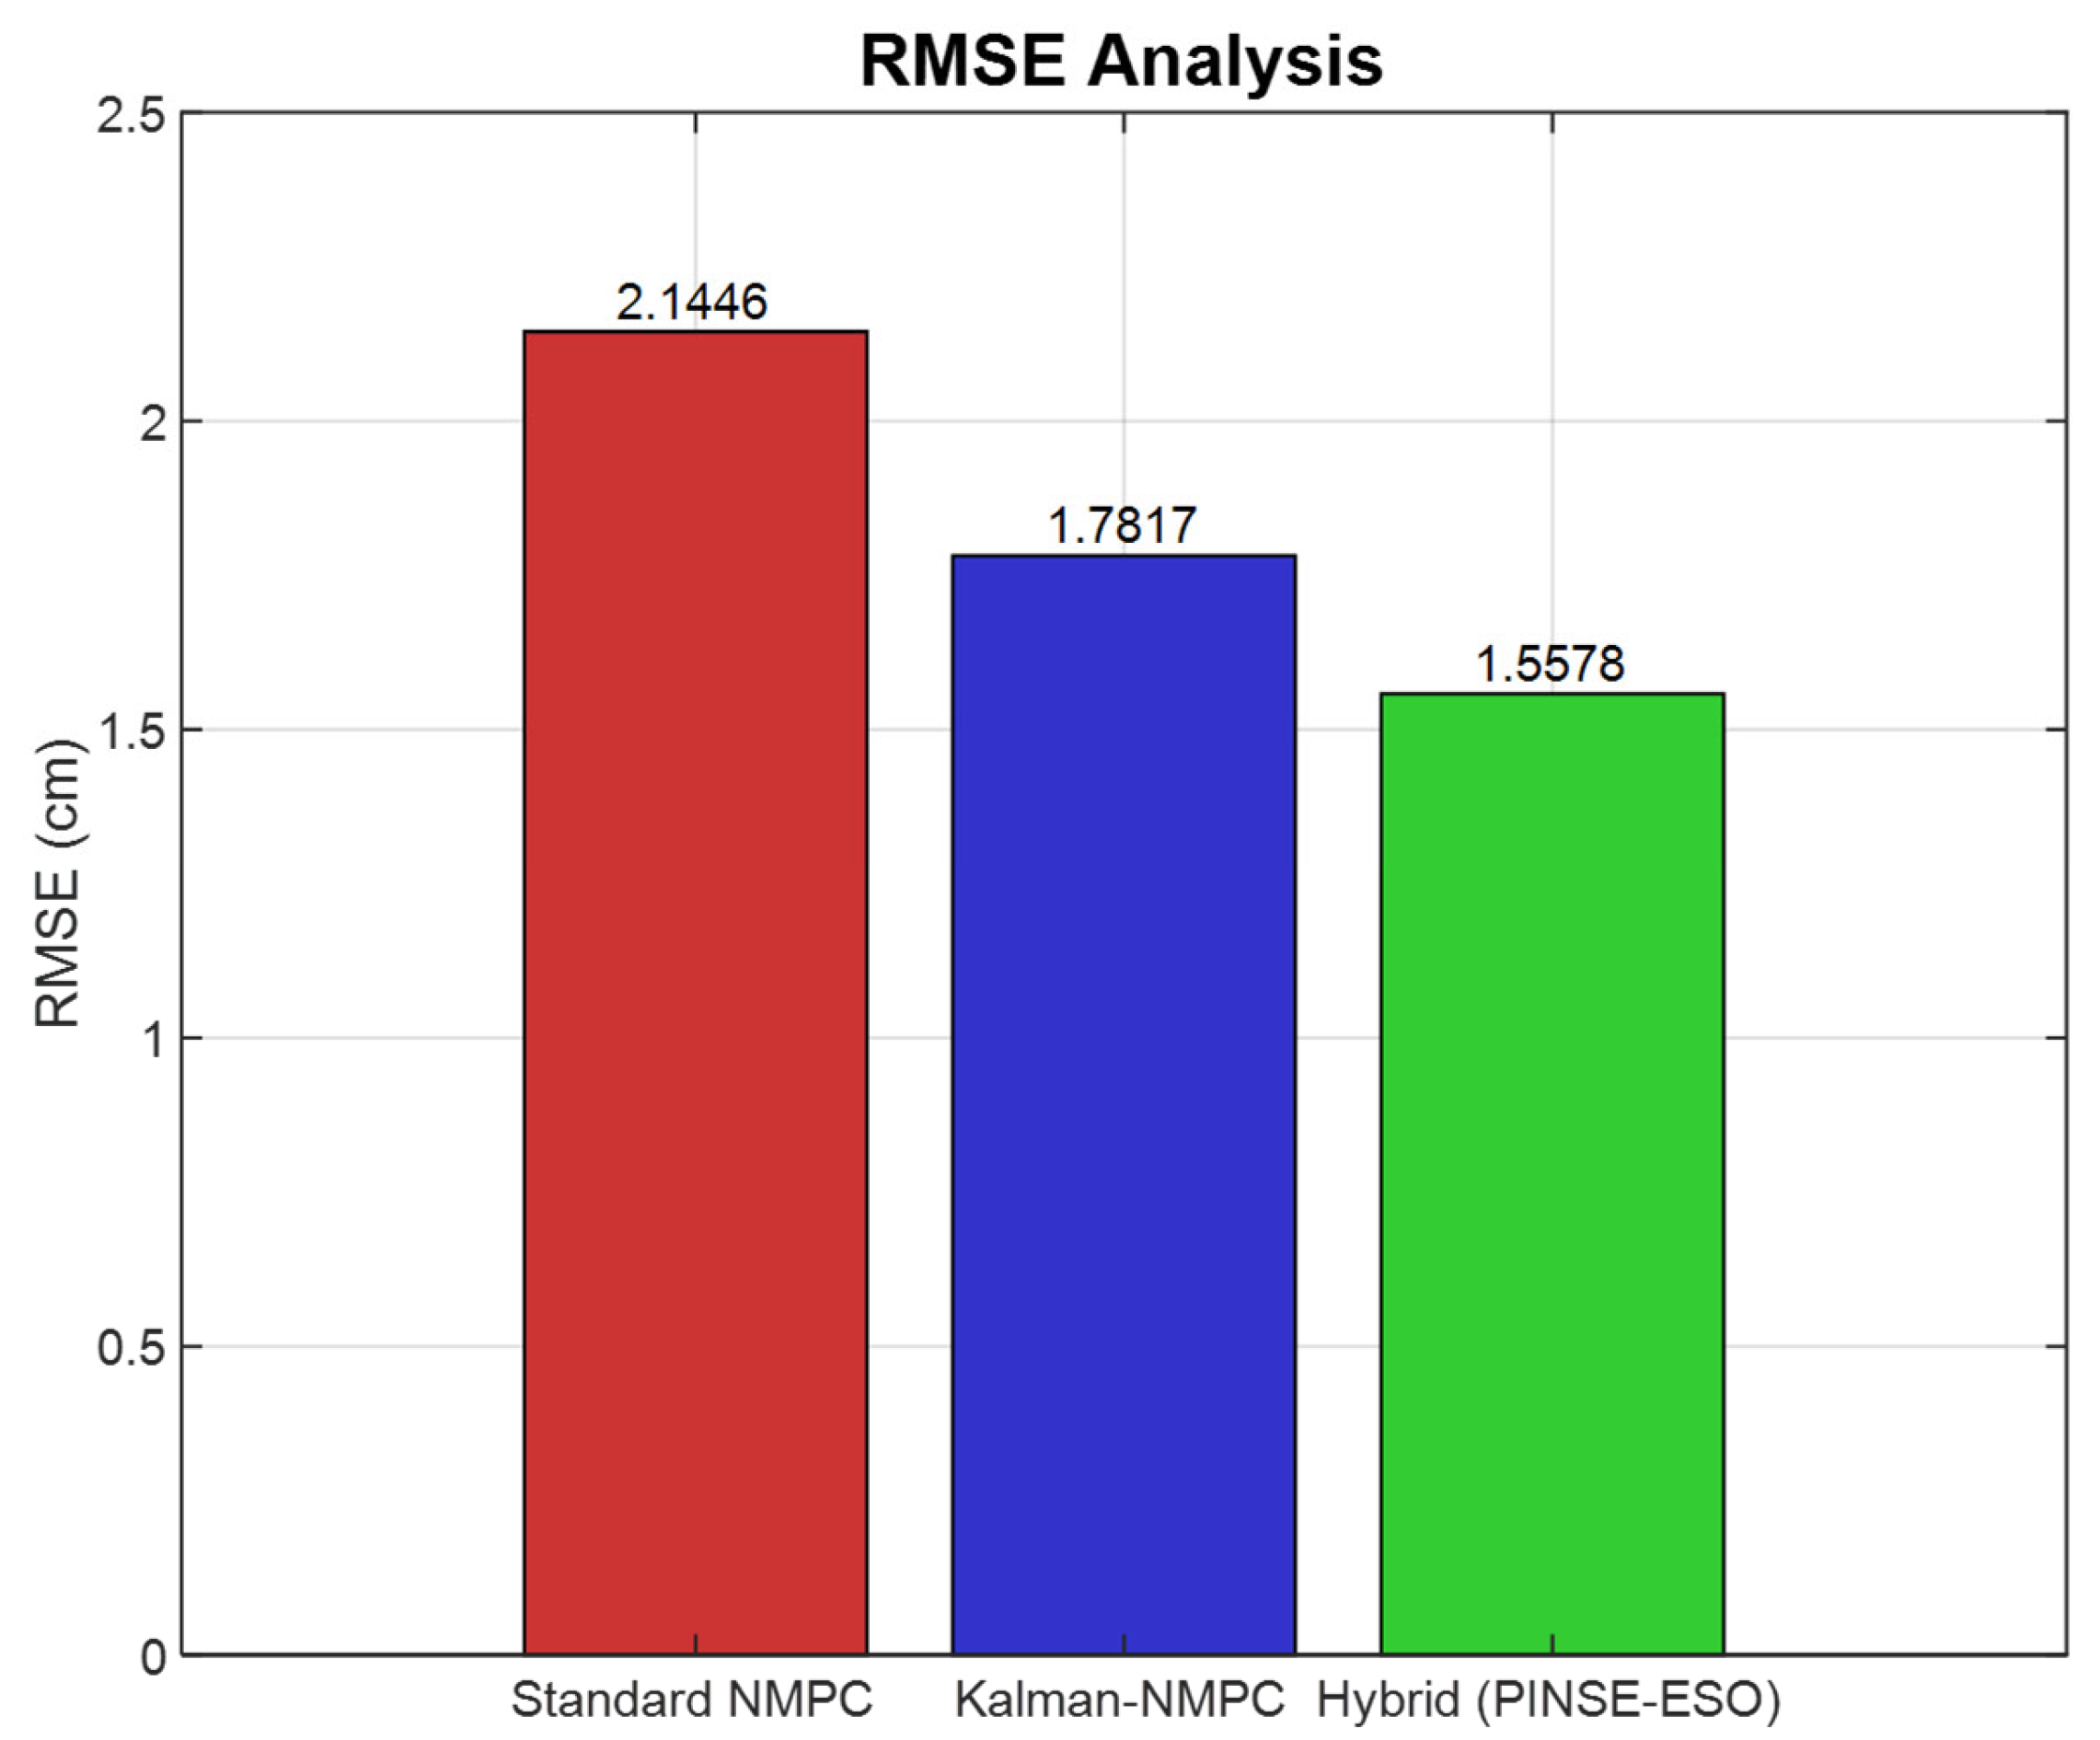
To provide a quantitative assessment, the Root Mean Square Error (RMSE) was calculated for the entire simulation duration. The results are visualized in Figure 4.
Figure 4.
Comparative analysis of the Root Mean Square Error (RMSE) for standard NMPC, Kalman-NMPC, and Hybrid (NMPC-ESO-PINSE).
The results of Tracking Performance and RMSE improvement for the three control strategies are summarized in Table 2.
Table 2.
Numerical comparison of Tracking Performance and RMSE improvement for the three control strategies.
As quantified in Table 2, the proposed hybrid (PINSE-ESO) architecture yields a +27.36% reduction in global RMSE compared to the standard NMPC, and a 16.92% improvement over the Kalman-NMPC framework.
Beyond accuracy, the operational advantages are highly pronounced: the settling time is cut by more than half compared to the standard controller, dropping to just . Most importantly, the proposed approach achieves this rapid regulation while reducing the cumulative control energy expenditure to . This reduction in actuator energy confirms that filtering noise through a physics-compliant manifold prevents aggressive pump voltage adjustments. It minimizes hardware stress and actuator wear, making the NMPC-ESO-PINSE architecture highly efficient for real-world industrial deployment.
7.2. Discussion
The quantitative and qualitative evaluation demonstrates the distinct capabilities of each control topology under severe operating constraints. The tracking trajectories validate that the standard NMPC achieves the poorest performance, characterized by high-frequency chattering and slow disturbance recovery. Because the linear approximations within the traditional Kalman filter fail to accurately capture the transient inverse response (undershoot) characteristic of non-minimum phase hydraulic plants, the controller exhibits a sluggish convergence rate toward the target references. Similar algebraic limitations regarding distributed multiparametric control designs, optimality condition decompositions, or specialized active observer couplings have been thoroughly documented in previous studies.
The proposed NMPC-ESO-PINSE framework effectively overcomes these structural limitations, achieving a +27.36% reduction in global RMSE compared to the standard NMPC and a 16.92% improvement over the Kalman–NMPC structure. This enhanced tracking accuracy performance is driven by the explicit synergy between its estimation and observation modules. The PINSE Block by embedding Bernoulli-based mass balance equations directly into the network mapping as a structural regularizer, the estimator restricts the reconstructed state trajectory to a physically invariant set. This regularizer prevents the controller from over-reacting to non-physical data artifacts, successfully distinguishing between true process disturbances and high-frequency sensor noise. The ESO block, acting as the active disturbance rejection layer, continuously estimates the lumped unmodeled dynamics (such as valve and pipe friction and pump pressure drops) as a total disturbance. This real-time estimate allows the NMPC loop to compute smooth, preemptive control efforts. Consequently, as detailed in the performance dashboard, the hybrid architecture dramatically compresses the settling time to and minimizes the transient overshoot to 0.18%.
Most notably, this enhanced tracking accuracy is accomplished alongside a significant reduction in cumulative control energy . This energy efficiency confirms that coupling physics-informed state reconstruction with extended state observation provides the necessary robustness for high-precision industrial applications where standard predictive algorithms fail.
The performance limitation profiles are strictly bound by the algebraic constraints of non-minimum phase systems. Since the four-tank system parameters satisfy the condition , the process operates within a multivariable non-minimum phase region. According to Bode’s Integral Constraint, a right half-plane (RHP) zero imposes an unavoidable physical ceiling on the closed-loop bandwidth that cannot be bypassed. Therefore, instead of claiming enhanced tracking accuracy, the proposed hybrid NMPC-ESO-PINSE framework focuses strictly on mitigating structural performance degradation by minimizing transient undershoot and cross-coupling delays. Due to these invariant physical barriers, the upper buffer reservoirs (Tank 3 and Tank 4) fundamentally exhibit a slower, ultimate bounded convergence, while the primary process variables (Tank 1 and Tank 2) stabilize rapidly without triggering actuator saturation.
8. Conclusions
In this research, a novel hybrid NMPC-ESO-PINSE control architecture was developed and implemented to achieve high-precision level regulation in a nonlinear four-tank system. The proposed framework successfully integrates a Nonlinear Model Predictive Control (NMPC) law with an Extended State Observer (ESO) for active disturbance rejection and a Physics-Informed Neural State Estimator (PINSE) for Bernoulli-compliant noise filtering.
The simulation results, conducted under a challenging non-minimum phase configuration, demonstrate that the proposed three-layer approach significantly improved the performance of both conventional NMPC and Kalman-filtered NMPC controllers. Specifically, the hybrid NMPC-ESO-PINSE architecture achieved a +27.36% reduction in global RMSE compared to standard NMPC and a 16.92% improvement over the Kalman-NMPC method. These results confirm that the PINSE-ESO block provides an enhanced tracking accuracy mechanism for real-time perturbation rejection and physically consistent state reconstruction.
Beyond tracking accuracy, the proposed framework exhibited remarkable robustness against stochastic uncertainties and unmodeled dynamics. It achieved rapid, non-oscillatory convergence to target setpoints with a settling time reduced by more than 50% . Furthermore, the substantial decrease in cumulative control energy confirms a significant reduction in actuator chattering and vibration, enhanced tracking accuracy performance and mechanical longevity.
In summary, the integration of physical knowledge within a predictive and adaptive framework proved to be a highly effective strategy for the control of complex, coupled, and non-minimum phase nonlinear systems. Future work will explore the deployment of this architecture on hardware-in-the-loop platforms to further validate its industrial feasibility.
Future Work
To further expand the capabilities and industrial applicability of the proposed NMPC-ESO-PINSE framework, several research directions will be pursued in future works.
First, the centralized control loop will be deployed on a hardware-in-the-loop (HIL) experimental setup or a physical micro-scale four-tank pilot plant to validate its real-time computational feasibility and assess the physical impact of communication latencies.
Second, while the current PINSE engine relies on offline training, future developments will focus on implementing an online adaptation mechanism for the neural network parameters. This will allow the physics-informed layer to dynamically update its weights in real time, enabling the controller to adapt to severe, long-term structural changes—such as internal component degradation or shifting operating bounds—without requiring offline recalibration.
Finally, exploring distributed or decentralized variants of this hybrid architecture represents a promising avenue to extend this robust control strategy to large-scale, interconnected water distribution networks.
Author Contributions
Software, Z.Z.; validation, E.M.A., M.Z. and A.B.; investigation, Z.Z.; writing—original draft preparation, Z.Z.; visualization, E.M.A.; supervision, M.Z. and A.B. All authors have read and agreed to the published version of the manuscript.
Funding
This research received no external funding.
Data Availability Statement
The original contributions presented in this study are included in the article. Further inquiries can be directed to the corresponding author.
Acknowledgments
During the preparation of this manuscript, the authors used Gemini 3.5 Flash (Google) to improve the language fluidity, translate sections from French to English, and optimize the structure of the entire text. The authors reviewed and edited the content and take full responsibility for the final manuscript.
Conflicts of Interest
The authors declare no conflicts of interest.
References
- Kortela, J. Model-Predictive Control for the Three-Tank System Utilizing an Industrial Automation System. ACS Omega 2022, 7, 17742–17748. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Ait-Saadi, A.; Meraihi, Y.; Soukane, A.; Ramdane-Cherif, A.; Benmessaoud Gabis, A. A novel hybrid chaotic Aquila optimization algorithm with simulated annealing for unmanned aerial vehicles path planning. Comput. Electr. Eng. 2022, 104, 108461. [Google Scholar] [CrossRef] [Scilit]
- Vashishth, M.; Rai, L.S.; Kumar, A.V.R. Liquid level control of coupled tank system using Fractional PID controller. Int. J. Emerg. Trends Electr. Electron. 2013, 3, 61–64. [Google Scholar]
- Bemporad, A.; Morari, M. Predictive Control of Constrained Hybrid Systems. In Nonlinear Model Predictive Control; Allgöwer, F., Zheng, A., Eds.; Birkhäuser: Basel, Switzerland, 2000; pp. 71–92. [Google Scholar]
- Stiasny, J.; Misyris, G.S.; Chatzivasileiadis, S. Physics-Informed Neural Networks for Non-linear System Identification for Power System Dynamics. arXiv 2020, arXiv:2004.04026. [Google Scholar] [CrossRef] [Scilit]
- Seborg, D.E.; Edgar, T.F.; Mellichamp, D.A.; Doyle, F.J. Process Dynamics and Control, 3rd ed.; John Wiley & Sons: Hoboken, NJ, USA, 2011. [Google Scholar]
- Di Ruscio, D. Model predictive control and identification: A linear state space model approach. In Proceedings of the 36th IEEE Conference on Decision and Control, San Diego, CA, USA, 12 December 1997; IEEE: Piscataway, NJ, USA, 1997; pp. 3202–3207. [Google Scholar] [CrossRef] [Scilit]
- Domański, P.D. Performance Assessment of Predictive Control—A Survey. Algorithms 2020, 13, 97. [Google Scholar] [CrossRef] [Scilit]
- Mishra, P.K.; Gasparino, M.V.; Chowdhary, G. Deep Model Predictive Control with Stability Guarantees. IEEE Trans. Autom. Control 2025, 70, 5460–5467. [Google Scholar] [CrossRef] [Scilit]
- Arcos-Legarda, J.; Gutiérrez, Á. Robust Model Predictive Control Based on Active Disturbance Rejection Control for a Robotic Autonomous Underwater Vehicle. J. Mar. Sci. Eng. 2023, 11, 929. [Google Scholar] [CrossRef] [Scilit]
- Findeisen, R.; Allgöwer, F. An introduction to nonlinear model predictive control. In Proceedings of the 21st Benelux Meeting on Systems and Control, Veldhoven, The Netherlands, 19–21 March 2002; Volume 11, pp. 119–141. Available online: https://www.eep.com.et/wp-content/uploads/2024/05/An_Introduction_to_Nonlinear_Model_Predictive_Cont.pdf (accessed on 10 March 2026).
- Garcia, C.E.; Prett, D.M.; Morari, M. Model predictive control: Theory and practice. Automatica 1989, 25, 335–348. [Google Scholar] [CrossRef] [Scilit]
- Bemporad, A.; Morari, M. Robust model predictive control: A survey. In Robustness in Identification and Control; Springer: London, UK, 1999; Volume 245, pp. 207–226. [Google Scholar]
- Geyer, T. Model Predictive Control of High Power Converters and Industrial Drives; John Wiley & Sons: Chichester, UK, 2017. [Google Scholar]
- Guo, B.Z.; Zhao, Z.L. On the convergence of an extended state observer for nonlinear systems with uncertainty. Syst. Control Lett. 2011, 60, 420–430. [Google Scholar] [CrossRef] [Scilit]
- Guo, B.Z.; Zhao, Z.L. Active Disturbance Rejection Control for Nonlinear Systems: An Introduction; Wiley-IEEE Press: Hoboken, NJ, USA, 2016. [Google Scholar] [CrossRef] [Scilit]
- Han, J. From PID to Active Disturbance Rejection Control. IEEE Trans. Ind. Electron. 2009, 56, 900–906. [Google Scholar] [CrossRef] [Scilit]
- Haseltine, E.L.; Rawlings, J.B. Critical evaluation of extended Kalman filtering and moving horizon estimation. Ind. Eng. Chem. Res. 2005, 44, 2451–2460. [Google Scholar] [CrossRef] [Scilit]
- Hofmann, T.; Hamar, J.; Rogge, M.; Zoerr, C.; Erhard, S.; Schmidt, J.P. Physics-Informed Neural Networks for State of Health Estimation in Lithium-Ion Batteries. J. Electrochem. Soc. 2023, 170, 090524. [Google Scholar] [CrossRef] [Scilit]
- Maxim, A.; Pauca, O.; Caruntu, C.-F. Distributed Model Predictive Control and Coalitional Control Strategies—Comparative Performance Analysis Using an Eight-Tank Process Case Study. Actuators 2023, 12, 281. [Google Scholar] [CrossRef] [Scilit]
- Johansson, K.H. The quad-tank process: A multivariable laboratory process with an adjustable zero. IEEE Trans. Control Syst. Technol. 2000, 8, 456–465. [Google Scholar] [CrossRef] [Scilit]
- Julier, S.J.; Uhlmann, J.K. Unscented filtering and nonlinear estimation. Proc. IEEE 2004, 92, 401–422. [Google Scholar] [CrossRef] [Scilit]
- Karniadakis, G.E.; Kevrekidis, I.G.; Lu, L.; Perdikaris, P.; Wang, S.; Yang, L. Physics-informed machine learning. Nat. Rev. Phys. 2021, 3, 422–440. [Google Scholar] [CrossRef] [Scilit]
- Kirubakaran, V.; Radhakrishnan, T.K.; Sivakumaran, N. Distributed multiparametric model predictive control design for a quadruple tank process. Measurement 2014, 47, 841–854. [Google Scholar] [CrossRef] [Scilit]
- Mayne, D.Q.; Michalska, H. Receding horizon control of nonlinear systems. IEEE Trans. Autom. Control 1990, 35, 814–824. [Google Scholar] [CrossRef] [Scilit]
- Mayne, D.Q.; Rawlings, J.B.; Rao, C.V.; Scokaert, P.O.M. Constrained model predictive control: Stability and optimality. Automatica 2000, 36, 789–814. [Google Scholar] [CrossRef] [Scilit]
- Fellani, M.A.; Gabaj, A.M. PID Controller Design for Two Tanks Liquid Level Control System Using Matlab. Int. J. Electr. Comput. Eng. 2015, 5, 436–442. [Google Scholar] [CrossRef] [Scilit]
- Nunes, G.C. Design and Analysis of Multivariable Predictive Control Applied to an Oil-Water-Gas Separator: A Polynomial Approach. Ph.D. Dissertation, University of Florida, Gainesville, FL, USA, 2001. [Google Scholar]
- Raissi, M.; Perdikaris, P.; Karniadakis, G.E. Physics-informed neural networks: A deep learning framework for solving forward and inverse problems involving nonlinear partial differential equations. J. Comput. Phys. 2019, 378, 686–707. [Google Scholar] [CrossRef] [Scilit]
- Raković, S.V.; Levine, W.S. Handbook of Model Predictive Control; Birkhäuser: Cham, Switzerland, 2019. [Google Scholar] [CrossRef] [Scilit]
- Rawlings, J.B.; Mayne, D.Q.; Diehl, M. Model Predictive Control: Theory, Computation, and Design, 2nd ed.; Nob Hill Publishing: Madison, WI, USA, 2017; Available online: https://sites.engineering.ucsb.edu/~jbraw/mpc/MPC-book-2nd-edition-5th-printing.pdf (accessed on 20 March 2026).
- Rossiter, J.A. Model-Based Predictive Control: A Practical Approach; CRC Press: Boca Raton, FL, USA, 2003. [Google Scholar]
- Roth, M. Kalman Filters for Nonlinear Systems and Heavy-Tailed Noise. Licentiate Thesis, Linköping University, Linköping, Sweden, 2013. Available online: https://www.diva-portal.org/smash/get/diva2:648389/FULLTEXT02.pdf (accessed on 20 March 2026).
- Saltık, M.B.; Yu, L.; Özkan, E.; Ljung, L. An outlook on robust model predictive control algorithms: Reflections on performance and computational aspects. J. Process Control 2018, 61, 77–102. [Google Scholar] [CrossRef] [Scilit]
- Schwenzer, M.; Ay, M.; Abel, D. Review on model predictive control: An engineering perspective. Int. J. Adv. Manuf. Technol. 2021, 117, 1327–1349. [Google Scholar] [CrossRef] [Scilit]
- Segovia, P.; Rajaoarisoa, L.; Nejjari, F.; Puig, V. Distributed model predictive control using optimality condition decomposition and community detection. J. Process Control 2021, 99, 54–68. [Google Scholar] [CrossRef] [Scilit]
- Xu, G.; Luo, S.; Huang, Y.; Deng, X. Extended State Observer Based Robust Nonlinear PID Attitude Tracking Control of Quadrotor with Lumped Disturbance. Processes 2025, 13, 1470. [Google Scholar] [CrossRef] [Scilit]
- Nair, A.S.; Janet Mary, S.A.; Linsely, J. Modeling and control of level control process—A comparative study. In Proceedings of the 2017 International Conference on Innovations in Power and Advanced Computing Technologies (i-PACT), Vellore, India, 21–22 April 2017; IEEE: Piscataway, NJ, USA, 2017; pp. 1–6. [Google Scholar]
- Li, R.; Zhu, M.; Zhu, Q.; Narayan, P.; Li, L. Disturbance-Observer-Based U-Control (DOBUC) for Nonlinear Dynamic Systems. Entropy 2021, 23, 1625. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Son, Y.S.; Kim, W. Robust Nonlinear Position Control with Extended State Observer for Single-Rod Electro-Hydrostatic Actuator. Mathematics 2021, 9, 2397. [Google Scholar] [CrossRef] [Scilit]
- Hanachi, H.; Liu, J.; Banerjee, A.; Chen, Y. Sequential state estimation of nonlinear/non-Gaussian systems with stochastic input for turbine degradation estimation. Mech. Syst. Signal Process. 2016, 72, 32–45. [Google Scholar] [CrossRef] [Scilit]
- Willard, J.; Zhong, X.; Karpatne, A.; Kumar, V. Integrating Scientific Knowledge with Machine Learning for Engineering and Environmental Systems. ACM Comput. Surv. 2022, 55, 66. [Google Scholar] [CrossRef] [Scilit]
- Xu, Z.; Deng, W. Extended-State-Observer-Based Adaptive Prescribed Performance Control for Hydraulic Systems with Full-State Constraints. IEEE Trans. Autom. Sci. Eng. 2022, 20, 1761–1772. [Google Scholar]
- Wang, S.; Gan, H.; Luo, Y.; Wang, X.; Gao, Z. Active disturbance rejection control with fractional-order model-aided extended state observer. ISA Trans. 2023, 142, 527–537. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Murray, R.M. Optimization-Based Control; California Institute of Technology: Pasadena, CA, USA, 2023; Available online: http://www.cds.caltech.edu/~murray/books/AM08/pdf/obc-complete_12Mar2023.pdf (accessed on 16 March 2026).
- Zhu, M.; Sun, W.; Wen, Y.; Huang, L. Extended State Observer-Based Parameter Identification of Response Model for Autonomous Vessels. J. Mar. Sci. Eng. 2022, 10, 1291. [Google Scholar] [CrossRef] [Scilit]
- Fang, H.; Haile, M.A.; Wang, Y. Robust Extended Kalman Filtering for Systems with Measurement Outliers. IEEE Trans. Control Syst. Technol. 2021, 30, 795–802. [Google Scholar] [CrossRef] [Scilit]
- Liang, F.; Pei, W. Active Disturbance Rejection Control for Nonlinear Systems Subject to Prescribed Performance Under Unknown Initial Tracking Conditions. Symmetry 2026, 18, 424. [Google Scholar] [CrossRef] [Scilit]
- Ma, T.N.; Xi, R.D. Nonlinear Extended State Observer Based Prescribed Performance Control for Quadrotor UAV with Attitude and Input Saturation Constraints. Machines 2022, 10, 551. [Google Scholar] [CrossRef] [Scilit]
- Yuan, X.; Wu, B.; Zheng, S.; Wang, Y. Design and parameter tuning of active disturbance rejection control for uncertain multivariable systems via quantitative feedback theory. ISA Trans. 2023, 142, 339–353. [Google Scholar]
- Ahmadi, N.; Cao, Q.; Humphrey, J.D.; Karniadakis, G.E. Physics-Informed Machine Learning in Biomedical Science and Engneering. Annu. Rev. Biomed. Eng. 2026, 28, 309–336. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Zhu, Y.; Zabaras, N.; Koutsourelakis, P.S.; Perdikaris, P. Physics-constrained deep learning for high-dimensional surrogate modeling and uncertainty quantification without labeled data. J. Comput. Phys. 2019, 394, 56–81. [Google Scholar] [CrossRef] [Scilit]
- Du, Z.; Lu, R. Physics-Informed Neural Networks for Advanced Thermal Management in Electronics and Battery Systems: A Review of Recent Developments and Future Prospects. Batteries 2025, 11, 204. [Google Scholar] [CrossRef] [Scilit]
- Ni, P.; Sun, L.; Yang, J.; Li, Y. Multi-End Physics-Informed Deep Learning for Seismic Response Estimation. Sensors 2022, 22, 3697. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Di, X.; Shi, R.; Mo, Z.; Fu, Y. Physics-Informed Deep Learning for Traffic State Estimation: A Survey and the Outlook. Algorithms 2023, 16, 305. [Google Scholar] [CrossRef] [Scilit]
- Speakman, J.; Papasavvas, A.; François, G. A robust modifier adaptation method via Hessian augmentation using model uncertainties. J. Process Control 2021, 99, 28–40. [Google Scholar] [CrossRef] [Scilit]
- Liu, X.; Lai, Y.G. Physics-Informed Deep Operator Learning for Computational Hydraulics Modeling. arXiv 2026, arXiv:2601.08086. [Google Scholar] [CrossRef] [Scilit]

Disclaimer/Publisher’s Note: The statements, opinions and data contained in all publications are solely those of the individual author(s) and contributor(s) and not of MDPI and/or the editor(s). MDPI and/or the editor(s) disclaim responsibility for any injury to people or property resulting from any ideas, methods, instructions or products referred to in the content. |
© 2026 by the authors. Licensee MDPI, Basel, Switzerland. This article is an open access article distributed under the terms and conditions of the Creative Commons Attribution (CC BY) license.