


Highlights
What are the main findings?
- Low-height aerial drone magnetometry (2 m above ground level) achieves 100% detection of ferromagnetic UXO (60–155 mm calibre) buried at <60 cm depth, with magnetic anomaly amplitudes of 2–18 nT and signal-to-noise ratios >5, despite extreme ferromagnetic contamination (>10 nT background noise) in active European training ranges.
- Geolocation accuracy of 0.5 m enables precise targeting of ground interventions, achieved through digital terrain model (DTM)-based following, diurnal correction, and advanced filtering of heading errors and platform oscillations.
What are the implications of the main findings?
- The method provides a safer alternative to ground-based techniques, eliminating personnel exposure to hazardous areas while achieving complete coverage of 0.53 ha in <1 h effective flight time (~50,000 measurement points/ha)—representing approximately 10-fold time reduction compared to manual surveys.
- The technology is scalable and operationally validated for integration into routine post-exercise inspection protocols and contaminated area management in European military training centres, with first documented application in an actively used 33,000 ha training range under realistic operational conditions.
Abstract
Unexploded ordnance (UXO) poses a significant hazard in controlled outdoor testing/training areas. This paper assesses the effectiveness of aerial drone-mounted magnetometry for detecting buried UXO located outside the designated landing areas of the National Training Center (CENAD) of San Gregorio (Zaragoza, Spain), considered the largest manoeuvre area in Europe. To this end, a high-resolution aeromagnetic survey was conducted using a GEM GSMP-35U proton magnetometer mounted on a hexacopter drone. Data were collected at flight heights of 7 m and 2 m above ground level along a grid with 1 m line spacing. For its validation, eleven UXOs were deliberately buried at known coordinates to evaluate the system’s sensitivity and spatial resolution under operational conditions. The results demonstrate the capability of aerial drone-based magnetometry to detect small magnetic anomalies (with amplitudes between 2 and 18 nT) associated with buried UXO in complex environments characterised by high ferromagnetic noise, achieving signal-to-noise ratios greater than 5 (SNR > 5) at 2 m height and a geolocation accuracy of approximately 0.5 m. These findings support the use of unmanned aerial magnetometry as a viable tool for identifying hazardous remnants in military training ranges and field scenarios, enabling coverage of 0.53 ha in less than one hour of effective flight time.
1. Introduction
Unexploded ordnance (UXO) remains a persistent hazard in controlled outdoor testing/training areas worldwide, posing risks to personnel safety, limiting land use, and generating long-term environmental impacts. In the Spanish Army’s National Training Centers (CENAD), where controlled high-energy discharge exercises with heavy large-calibre devices are routinely conducted, a non-negligible proportion of metallic cylindrical objects either fail to detonate or land outside designated landing areas due to ballistic deviations, weapon-system malfunction, or adverse meteorological conditions. The detection and clearance of UXO in these environments is therefore a critical operational requirement.
Historically, UXO localisation has relied primarily on ground-based methods, including handheld or cart-mounted magnetometry and electromagnetic induction (EMI) systems [1,2,3]. Although these techniques offer high spatial resolution, they involve substantial logistical effort, expose personnel to hazardous terrain, and become inefficient or impractical in areas with dense vegetation, complex topography, or extensive ferromagnetic debris. These limitations have driven the development of aerial drones equipped with high-sensitivity magnetometers, which provide an appealing combination of spatial resolution, broad aerial coverage, and improved operator safety. Recent advances in sensor miniaturisation, flight control stability, and multirotor autonomy have enabled high-density aeromagnetic surveying at very low heights over complex and potentially dangerous terrain [4,5,6]. Aerial drones-based magnetic surveys are particularly advantageous in environments characterised by intense superficial ferromagnetic contamination—such as shrapnel, cartridge casings, and target fragments—where precise discrimination between background noise and anomalies associated with buried UXOs is essential [7,8,9].
1.1. Brief State of the Art
1.1.1. Magnetic Detection Principles
Magnetometry detects perturbations in the ambient geomagnetic field generated by ferromagnetic bodies whose magnetic susceptibility contrasts sharply with surrounding materials. Foundational geophysical texts [8,10] describe how artillery shells and similar UXO types produce dipolar anomalies whose amplitude decreases with the cube of the distance between sensor and target, imposing stringent requirements on sensor sensitivity and survey height. Modern overviews of magnetic methods [11] highlight the continuous evolution from 19th-century magnetic balances to contemporary high-precision proton-precession and optically pumped magnetometers, emphasising that UXO detection—given typical projectile diameters of 50–155 mm and shallow burial depths—requires sensitivities on the order of ≤0.01 nT and dense spatial sampling. These works also underscore the importance of correcting magnetic measurements for diurnal geomagnetic variations and anthropogenic noise, which are essential to enhancing SNR in UXO applications.
1.1.2. Conventional Ground and Airborne UXO Detection
Ground-based geophysical techniques—magnetometry, EMI, and ground-penetrating radar (GPR)—remain standard in operational demining due to their proximity to the target and resulting high sensitivity. However, they are slow, labour-intensive, and potentially hazardous. Early helicopter-borne aeromagnetic surveys demonstrated the potential to rapidly delimit contaminated areas, though flight heights of 30–50 m significantly limited detection of small UXO [3,12]. These pioneering studies established key principles: (i) helicopter magnetometry is effective for regional reconnaissance; (ii) detection of small-calibre UXO requires sensor–target distances of only a few metres; and (iii) integrating complementary methods (e.g., magnetometry and GPR) improves depth estimation and target characterisation [9].
These insights motivated the exploration of low-height, high-resolution unmanned systems as an intermediate solution between broad-scale airborne reconnaissance and fine-scale ground surveys.
1.1.3. Aerial Drone Platforms for High-Resolution Magnetometry
The integration of high-sensitivity magnetometers with aerial multirotor drones has substantially expanded the capability of magnetic surveying. Aerial drones provide unique operational advantages: hovering capability, low-speed flight (1–10 m/s), heights of 1–10 m above ground level, and centimetre-level trajectory control via precise Global Navigation Satellite System (GNSS) and inertial measurement units (IMUs).
However, aerial drone-based magnetometry presents challenges absent in manned aircraft. Attitude variations (pitch, roll, yaw) can introduce orientation-dependent errors—particularly in optically pumped magnetometers—and magnetic interference from onboard ferromagnetic components can generate perturbations of 10–50 nT at short distances [13]. Best-practice guidelines [4,14] include (i) suspending the magnetometer ≥ 2 m below the aerial drone on a nonmagnetic arm; (ii) characterising the aerial drone’s magnetic signature; (iii) applying IMU-based attitude corrections; and (iv) conducting surveys under moderate wind and controlled speeds. These measures are now widely adopted as standard protocol [15].
1.1.4. Applications of Aerial Drone Magnetometry to UXO Detection
In the last decade, aerial drone-mounted magnetometry has been increasingly tested in post-conflict areas and active large-scale outdoor ranges [5,16,17,18]. One of the most rigorous studies to date was conducted in the Korean Demilitarised Zone (DMZ) [6], where a DJI Matrice 600 carrying a GEM GSMP-35U proton magnetometer (the same sensor used in the present study) surveyed calibrated UXO test fields. Systematic tests at 2, 5, and 10 m above ground level demonstrated the cube-law attenuation predicted by magnetic theory [11]: 100% detection at 2 m, 85% at 5 m, and only 45% at 10 m, with corresponding decreases in anomaly amplitude and increases in positional error. The results established ≤3 m above ground level as the operational threshold for reliable detection of medium-calibre UXO (<120 mm), influencing subsequent international demining protocols. Recently, other authors [19] evaluated the effectiveness of aerial drone-based magnetic surveys for unexploded ordnance detection, showing that while ferrous objects are reliably identified, widespread plastic ordnance and blast-induced anomalies complicate interpretation. The initial findings highlight both the potential and limitations of aerial drone magnetic systems in contaminated environments.
Hybrid systems combining aerial drone magnetometry with terrestrial time-domain electromagnetic (TEM) surveys have also proven effective [5]. While aerial drone magnetometry rapidly highlights ferromagnetic anomalies, TEM data allow for discrimination between UXO and scrap metal based on their characteristic electromagnetic decay properties. This combined approach reduced false positives from 43% to 25% in controlled tests, substantially lowering excavation costs and operational burden.
Last but not least, other authors [20] presented the integration of multiple three-axis fluxgate magnetometers into a hovering autonomous underwater drone for UXO detection. By enabling low-speed, near-seafloor surveys and direct magnetic gradient measurements, the approach demonstrates the potential of underwater drone-based magnetometry for high-resolution underwater UXO mapping.
1.1.5. Sensor Technologies for Aerial Drone Magnetometry
Comparative studies of magnetometer technologies—proton precession, optically pumped alkali-vapour, and fluxgate sensors—have clarified their relative strengths and limitations for aerial drone deployment [15]. Proton magnetometers offer high absolute sensitivity and orientation-independence at moderate cost, making them suitable for UXO detection at ≤1 m depth. Optically pumped caesium systems support high sampling rates and are advantageous for high-speed surveys, but are costlier and orientation-sensitive. Fluxgate magnetometers, while inexpensive and robust, lack the sensitivity required for detecting small UXOs at more than minimal heights. Experimental comparisons confirm that proton and caesium sensors detect nearly all UXOs at ≤3 m above ground level, whereas fluxgate systems perform poorly above ~2 m.
1.1.6. Advances in Magnetic Data Processing
Quantitative interpretation of magnetic anomalies requires advanced processing techniques, notably 3D magnetic inversion. Some authors [21,22] introduced algorithms that remain the methodological standard for estimating subsurface susceptibility distributions and target depth. Although challenges persist—such as anomaly superposition and noise introduced by dense ferromagnetic debris—these inversion methods can estimate UXO depth with ±15–20% error, sufficiently accurate to guide excavation priorities [23]. To advance in this data processing pipeline, other authors [24] introduced a recursive difference inversion technique for scalar magnetic data collected by aerial drone platforms, generalising classical along-track gradients to accommodate arbitrary sensor motion. This method allows direct inversion of magnetic differences with minimal pre-processing, demonstrating improved handling of disturbances and better visualisation of subsurface anomalies. The same main author [25] demonstrated the feasibility of high-speed, multi-sensor aerial drone magnetic surveys for UXO detection, validating a towed scalar magnetometer system capable of acquiring dense, low-noise data. While the study provides a thorough assessment of system performance and noise characteristics, its validation is mainly limited to controlled test sites, leaving challenges related to complex geological settings and operational environments largely unaddressed.
1.1.7. Advanced Processing Techniques for Noisy Environments
Recent advances in magnetic data processing have emphasised the importance of directional filtering and noise removal techniques for enhancing weak anomalies in cluttered environments. In [26], the authors introduced wavelet-based methods for regional-residual separation of potential field anomalies, enabling the isolation of shallow sources from deeper geological backgrounds. Building on this foundation, Fedi and Florio [27] developed decorrugation techniques using wavelet transforms to remove directional trends and flight-line noise—artefacts commonly observed in aeromagnetic surveys that can mask genuine anomalies. For aerial drone-based magnetometry, these processing challenges are amplified by platform instabilities. In fact, Walter et al. [4] demonstrated that three-dimensional attitude variations (pitch, roll, yaw) introduce systematic errors that must be corrected prior to interpretation. More recently, some authors [28] conducted comparative analyses of aerial drone-mounted magnetometre systems, confirming that proper handling of heading errors and payload oscillations is essential for reliable UXO detection. In this line, some authors [29] further applied these principles to archaeological prospection, showing that drone-borne gradiometry combined with advanced filtering can resolve sub-meter targets even in magnetically complex terrain. These methodological refinements underscore that successful aerial drone magnetometry depends not only on sensor quality and flight planning, but critically on the implementation of robust data-processing workflows tailored to the specific noise characteristics of low-height surveys.
1.2. Research Gaps and Study Motivation
Although the application of aerial drone-based magnetometry for UXO detection has been widely investigated, its performance under realistic operational conditions remains insufficiently documented. In particular, most published studies rely on test sites with relatively clean magnetic backgrounds, which do not reflect the complexity of active military ranges. In contrast, modern training areas are characterised by dense shrapnel, metallic debris, and heterogeneous geology, often producing magnetic noise levels exceeding 10 nT and severely degrading signal-to-noise ratios [30,31,32]. As a result, the robustness of aerial drone magnetometry in such low-SNR environments is still an open question.
Additional gaps persist in the literature, including (i) the lack of systematic evaluation of flight height in rugged terrain with intense ferromagnetic clutter; (ii) limited ground-truth validation using geodetically verified UXO locations and quantitative performance metrics [33]; (iii) scarce applications within European geomagnetic and regulatory frameworks, where differences in magnetic inclination (60–65°), airspace regulations, and standardised ordnance types require region-specific validation; and (iv) the absence of end-to-end operational workflows suitable for routine military use, as most studies focus on isolated components rather than fully integrated methodologies [34].
Against this backdrop, the present work specifically investigates aerial drone-mounted magnetometry in the CENAD San Gregorio (Zaragoza, Spain), one of the largest active controlled outdoor training areas in Europe and a representative worst-case scenario for UXO detection due to its intense ferromagnetic contamination and complex topography. A high-sensitivity GEM GSMP-35U proton magnetometer mounted on a hexacopter was deployed at very low flight heights (2–7 m) to assess detection capabilities under extremely low signal-to-noise conditions. Particular emphasis is placed on the technical methodology and data-processing workflow required to recover weak magnetic anomalies in such environments, integrating diurnal correction, noise filtering, spectral transformations (Reduction to the Pole, analytic signal), and 3D magnetic susceptibility inversion. This end-to-end workflow constitutes a key contribution of the study and demonstrates the feasibility and limitations of aerial drone magnetometry when applied to highly contaminated, operationally realistic military ranges.
2. Materials and Methods
2.1. Study Area
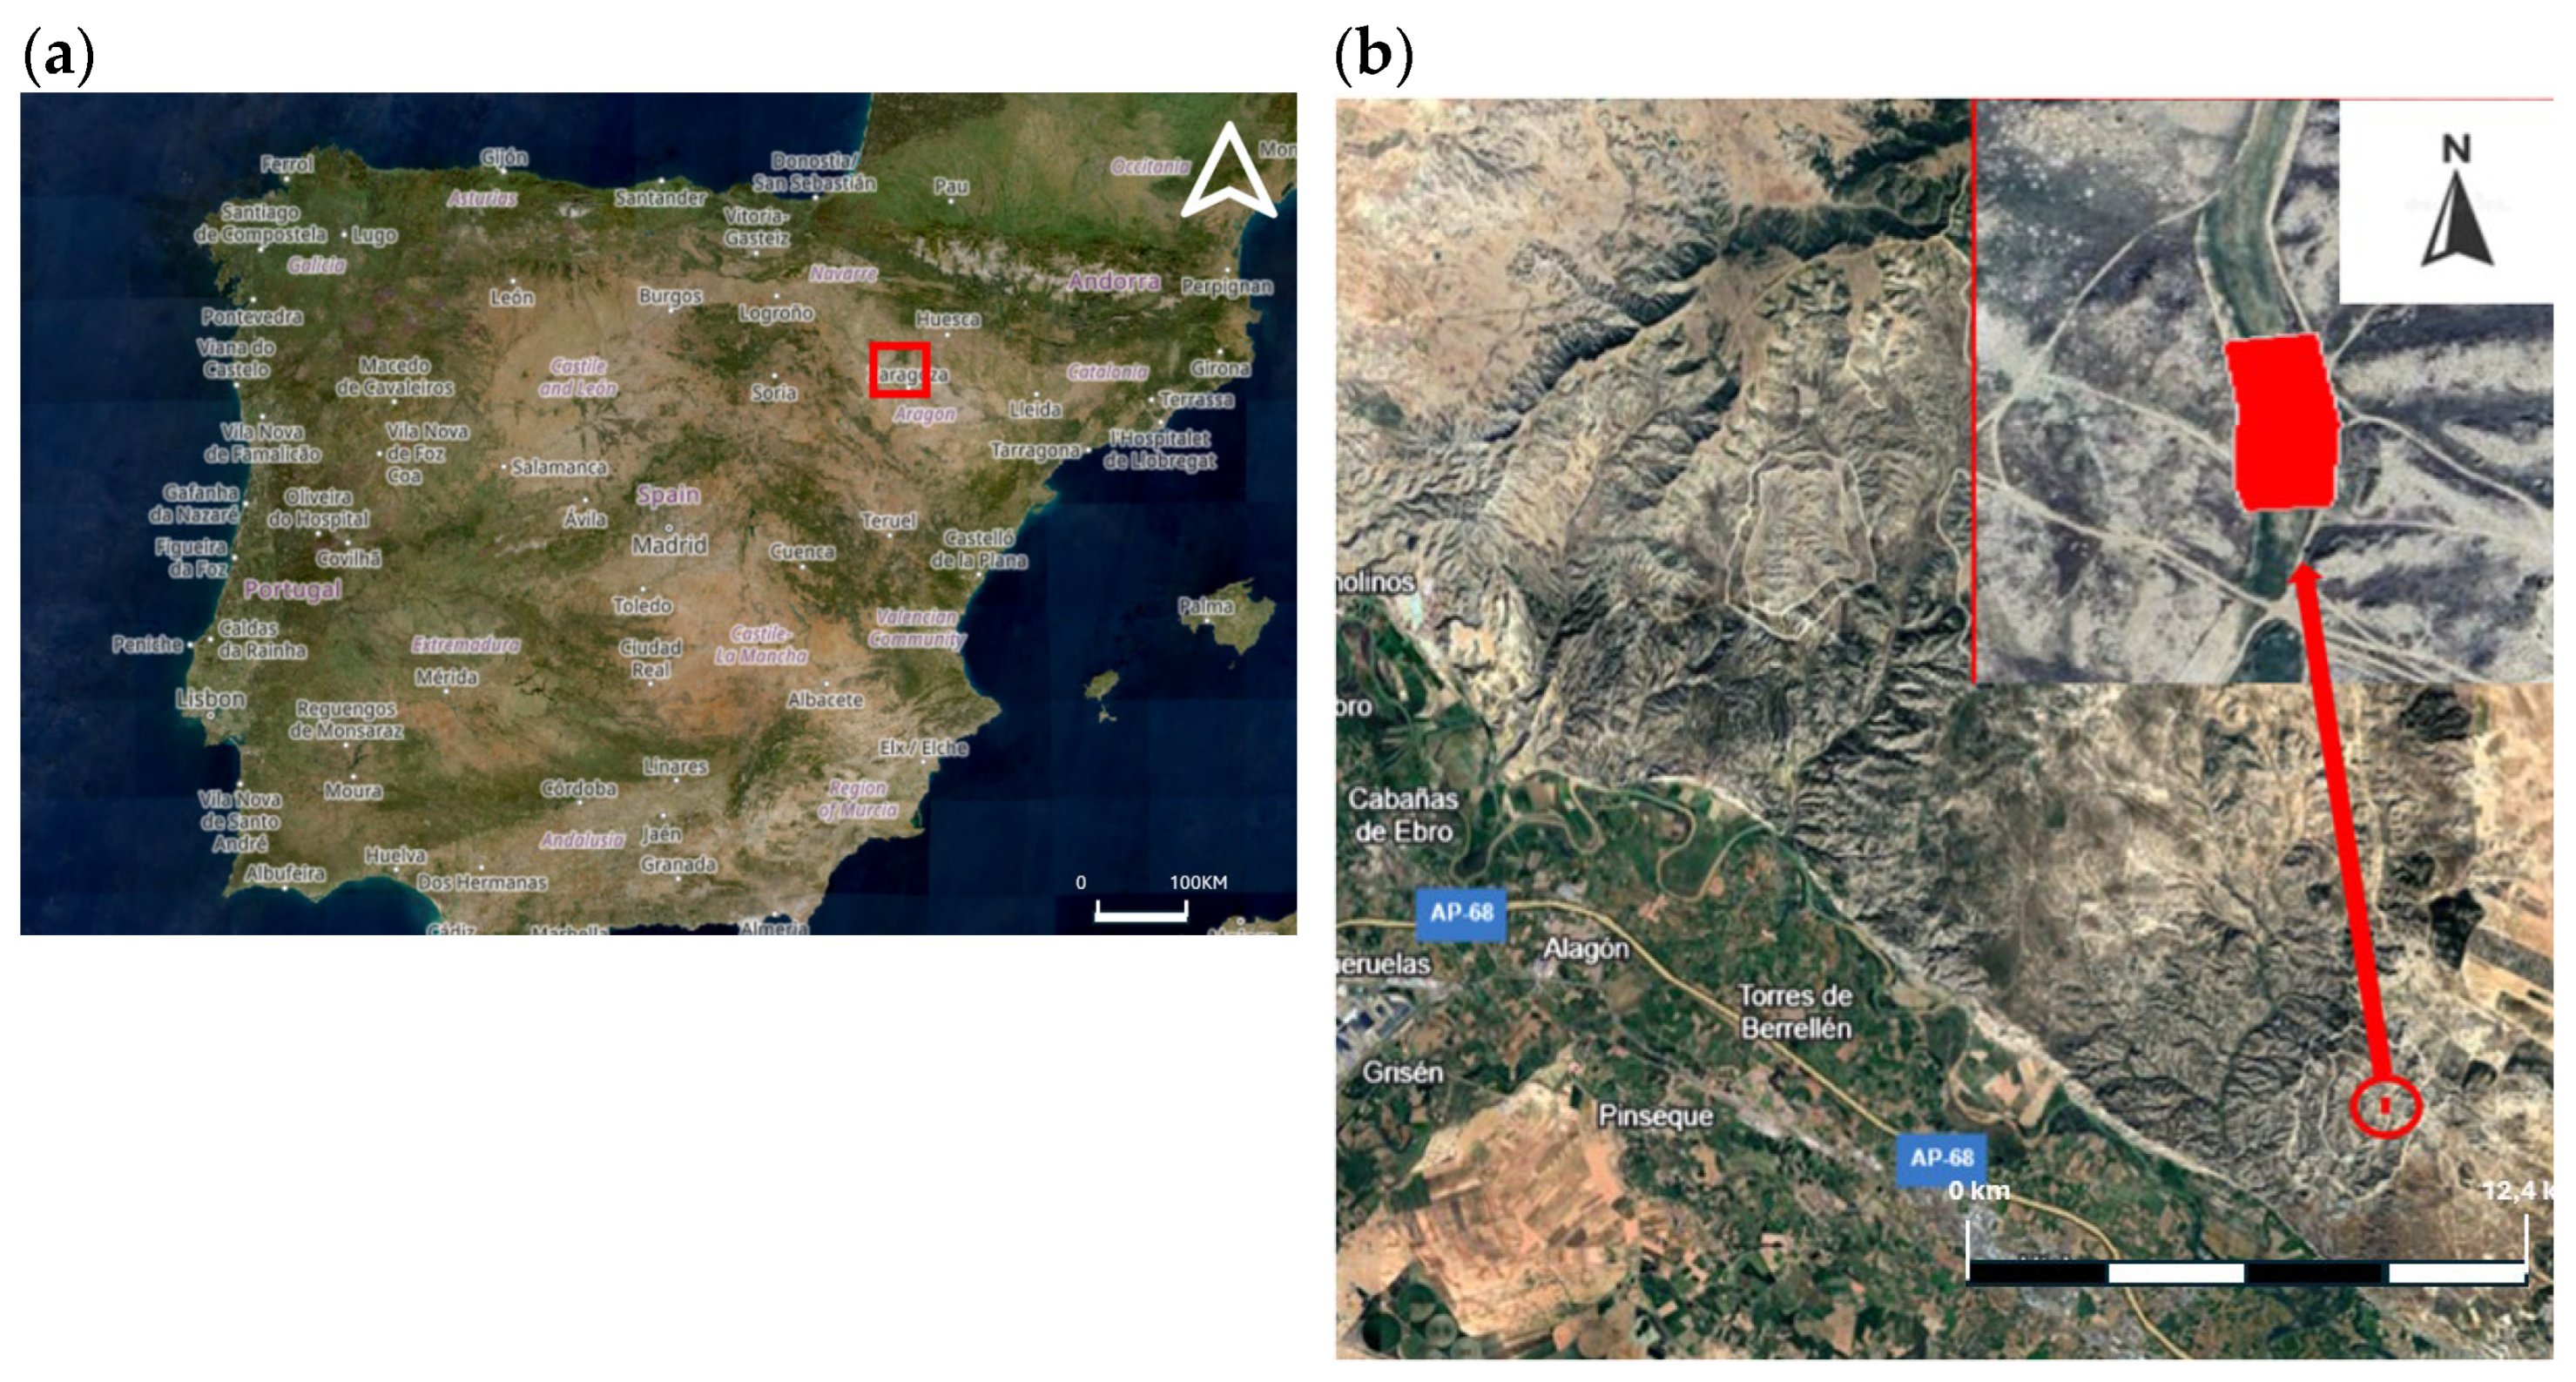
The field experiment was conducted at the San Gregorio National Training Center (Centro de Adiestramiento de San Gregorio, CENAD), located near Zaragoza, Spain (Figure 1a). The training area covers approximately 33,000 ha (340 km2) and is considered the largest manoeuvre range in Europe, with a perimeter of about 108 km. The selected test site is characterised by gently undulating topography, sparse steppe-type vegetation (Figure 1b), and a high density of metallic debris associated with controlled high-energy discharge exercises, providing an ideal setting to evaluate aeromagnetic survey techniques in a complex, noise-contaminated environment [35].
Figure 1.
(a) Location map of Zaragoza within Spain, obtained from Google Maps, showing the regional context of the study area. (b) High-resolution orthophoto of the San Gregorio CENAD showing the specific 0.53 ha test area (red polygon) located on the perimeter firebreak of the F-23 projectile designated landing area. Scale bar and north arrow provided for spatial reference. Coordinate system: WGS84/UTM Zone 30N.
The particular sector chosen for the experimental survey exhibits low direct anthropogenic interference, limited ground accessibility via unpaved tracks, and a moderate density of superficial ferromagnetic elements, making it suitable for validating aerial drone-based aeromagnetic methods under realistic field conditions (Figure 1b).
2.2. Experimental Design
To assess the detection capability of the aerial drone–magnetometer system, a set of 11 unexploded ordnance (UXO) surrogates of different diameters and morphologies (60, 81, 105, 120, and 155 mm) were deliberately buried at known positions within the study area. Burial depths ranged from 20 to 60 cm, reproducing realistic field conditions encountered in active military training ranges.
The main characteristics of the metallic cylindrical objects used in the experimental campaign—including calibre, burial depth, material, orientation, approximate mass, and ferrous content—are summarised in Table 1.
Table 1.
Characteristics of the UXO surrogates buried for the experimental survey.
In addition to ferromagnetic munitions, an anti-tank projectile with a plastic (non-ferrous) body was included as a negative control to verify the absence of magnetic response from non-ferromagnetic objects. All ferromagnetic metallic cylindrical objects were buried at geodetically surveyed coordinates to enable quantitative validation of the detection results.
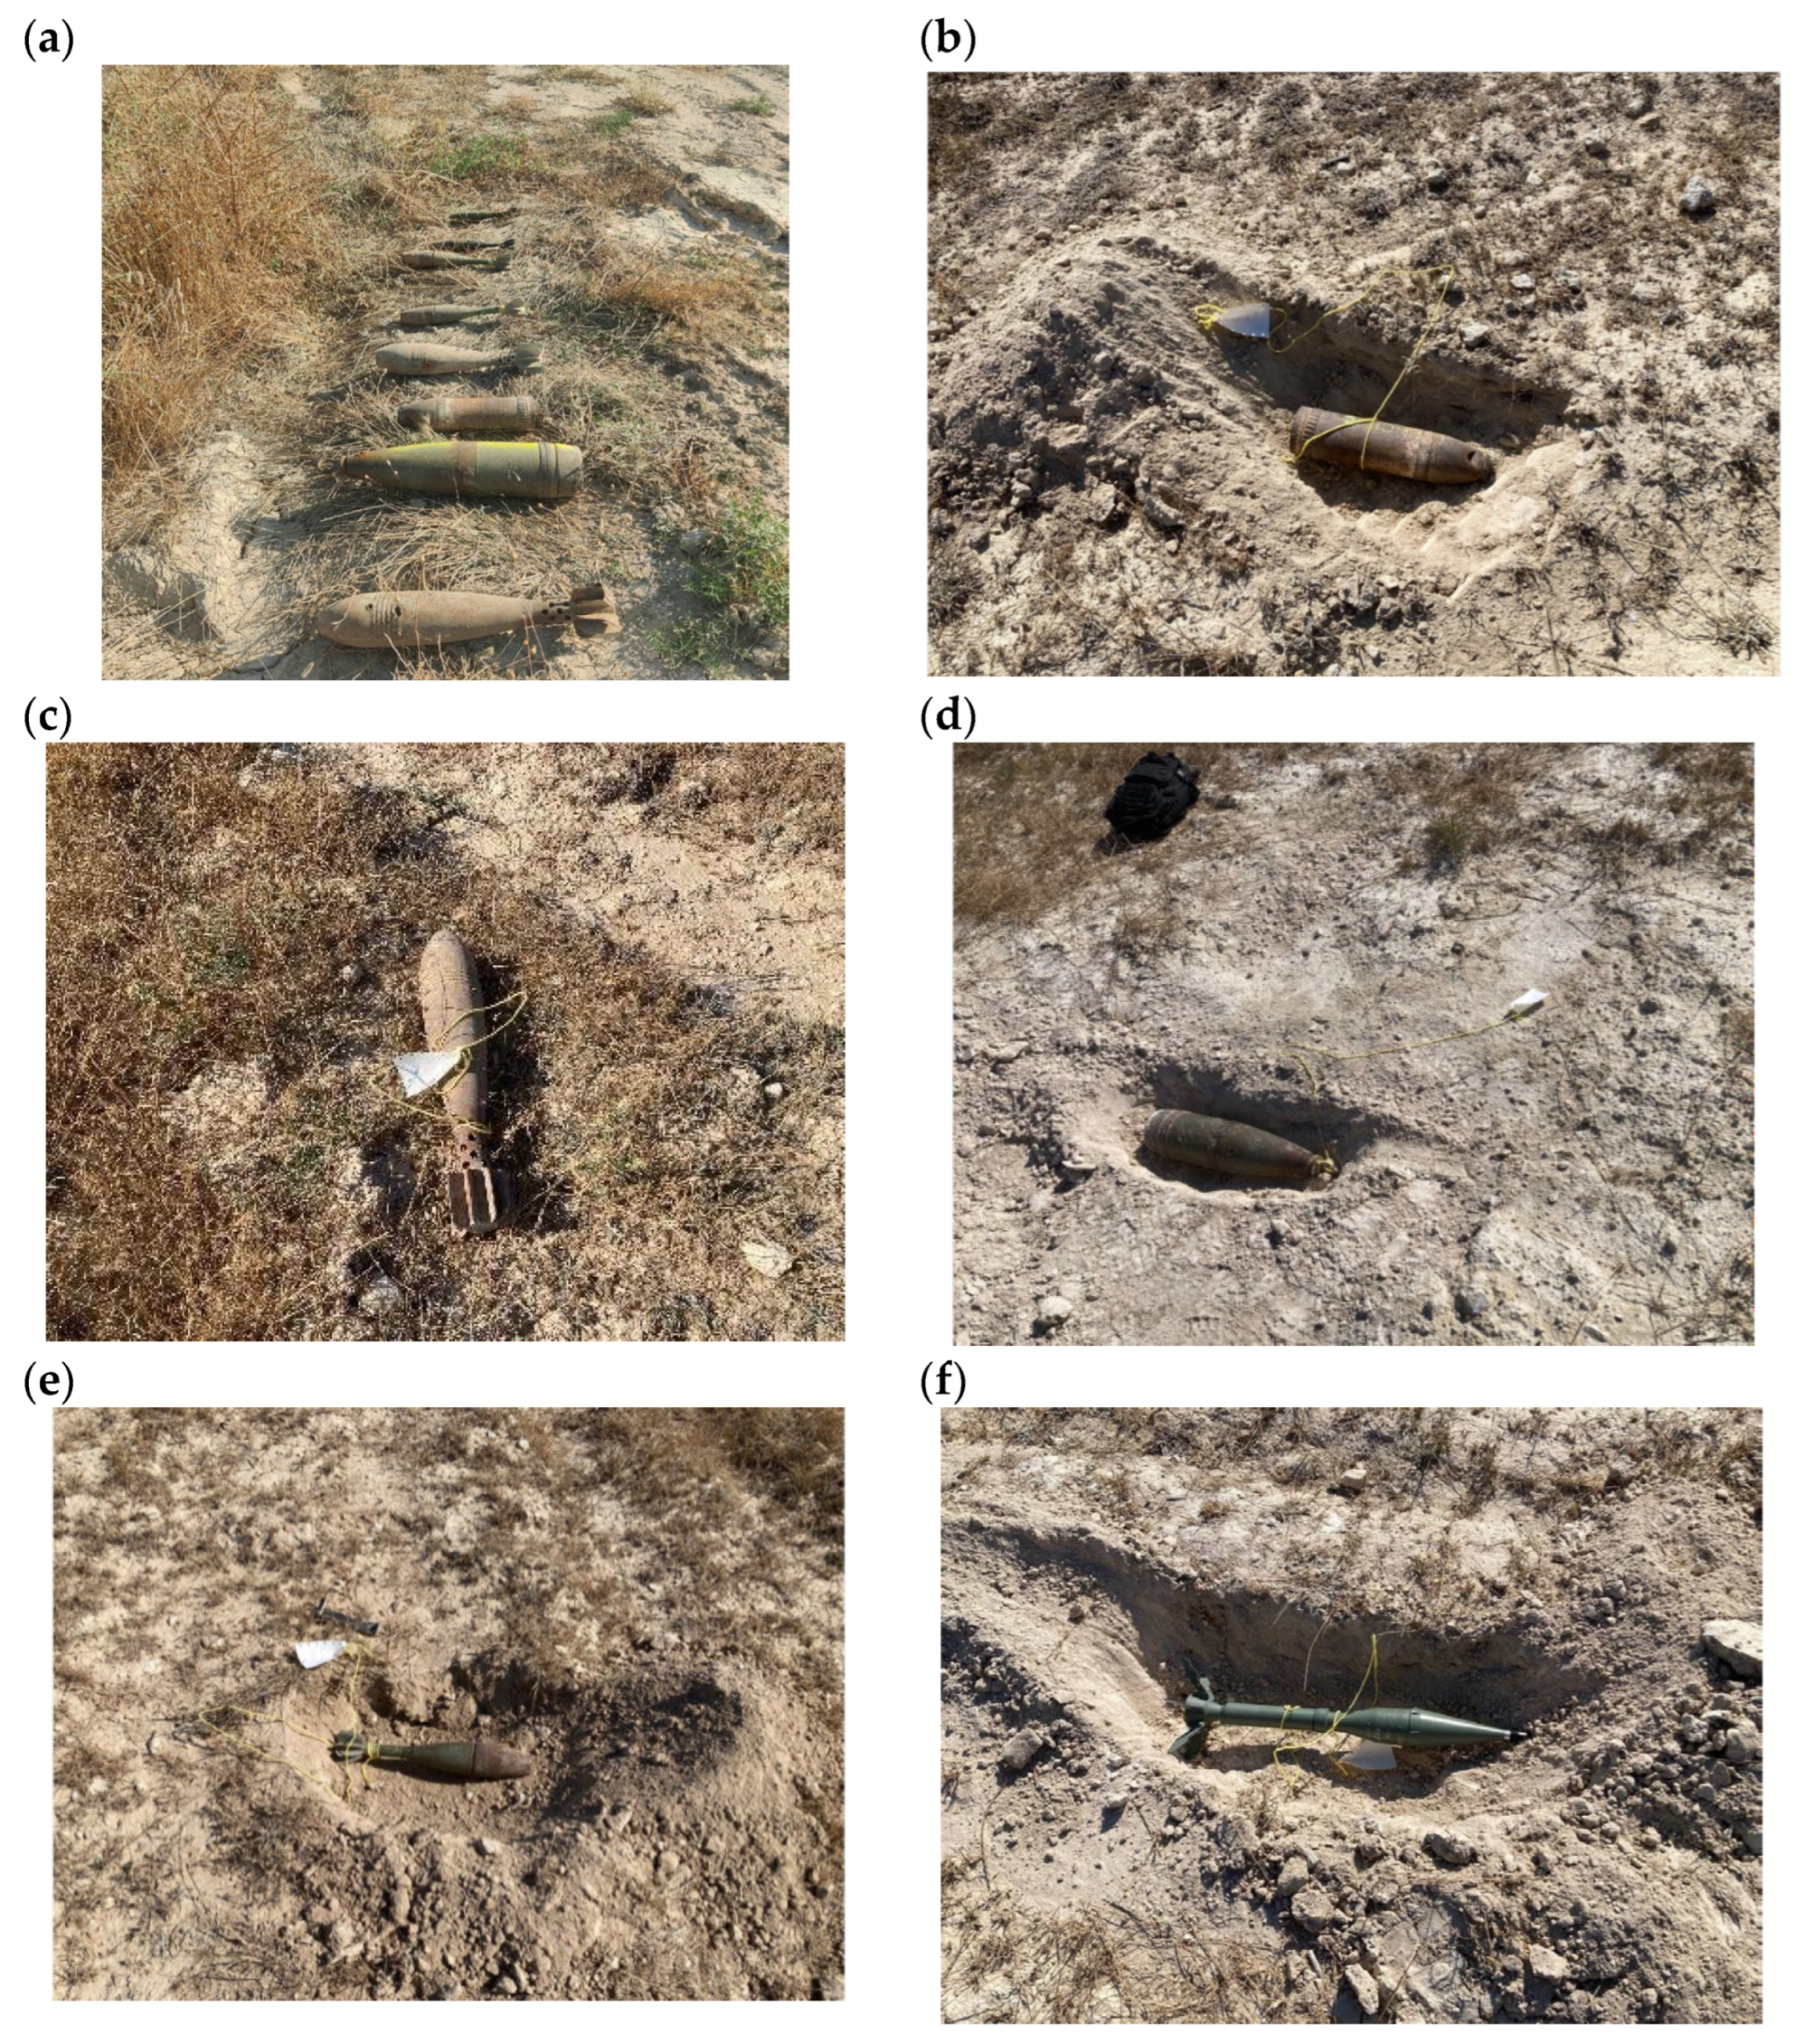
Representative photographs of the different metallic cylindrical objects and their emplacement in the field are presented as a mosaic in Figure 2a–f, including the full set of UXO surrogates, the 105 mm projectile and its placement, the 120 mm mortar shell in vertical orientation, the 155 mm projectile, the 60 mm mortar shell, and the negative-control anti-tank projectile during installation.
Figure 2.
(a) Set of metallic cylindrical objects used in the experimental campaign to simulate buried UXO. (b) A 105 mm projectile and detail of its placement in the ground during the test. (c) A 20 mm mortar round placed in a vertical position for data collection. (d) A 155 mm projectile and detail of its placement in the ground. (e) A 60 mm mortar round and detail of its placement in the ground. (f) Details of the placement process for the negative-control anti-tank projectile.
The UXO surrogates were distributed in a dispersed pattern over an area of 0.53 ha, aligned with the existing perimeter firebreak. This layout facilitated the design of flight lines and maximised effective magnetic coverage while maintaining operational safety for the aerial drone platform.
2.3. Acquisition Platform
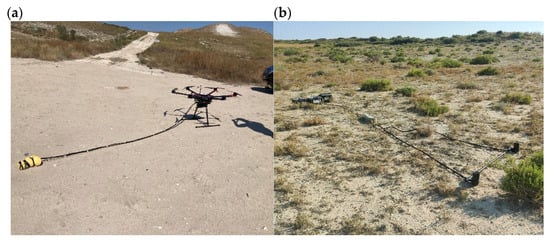
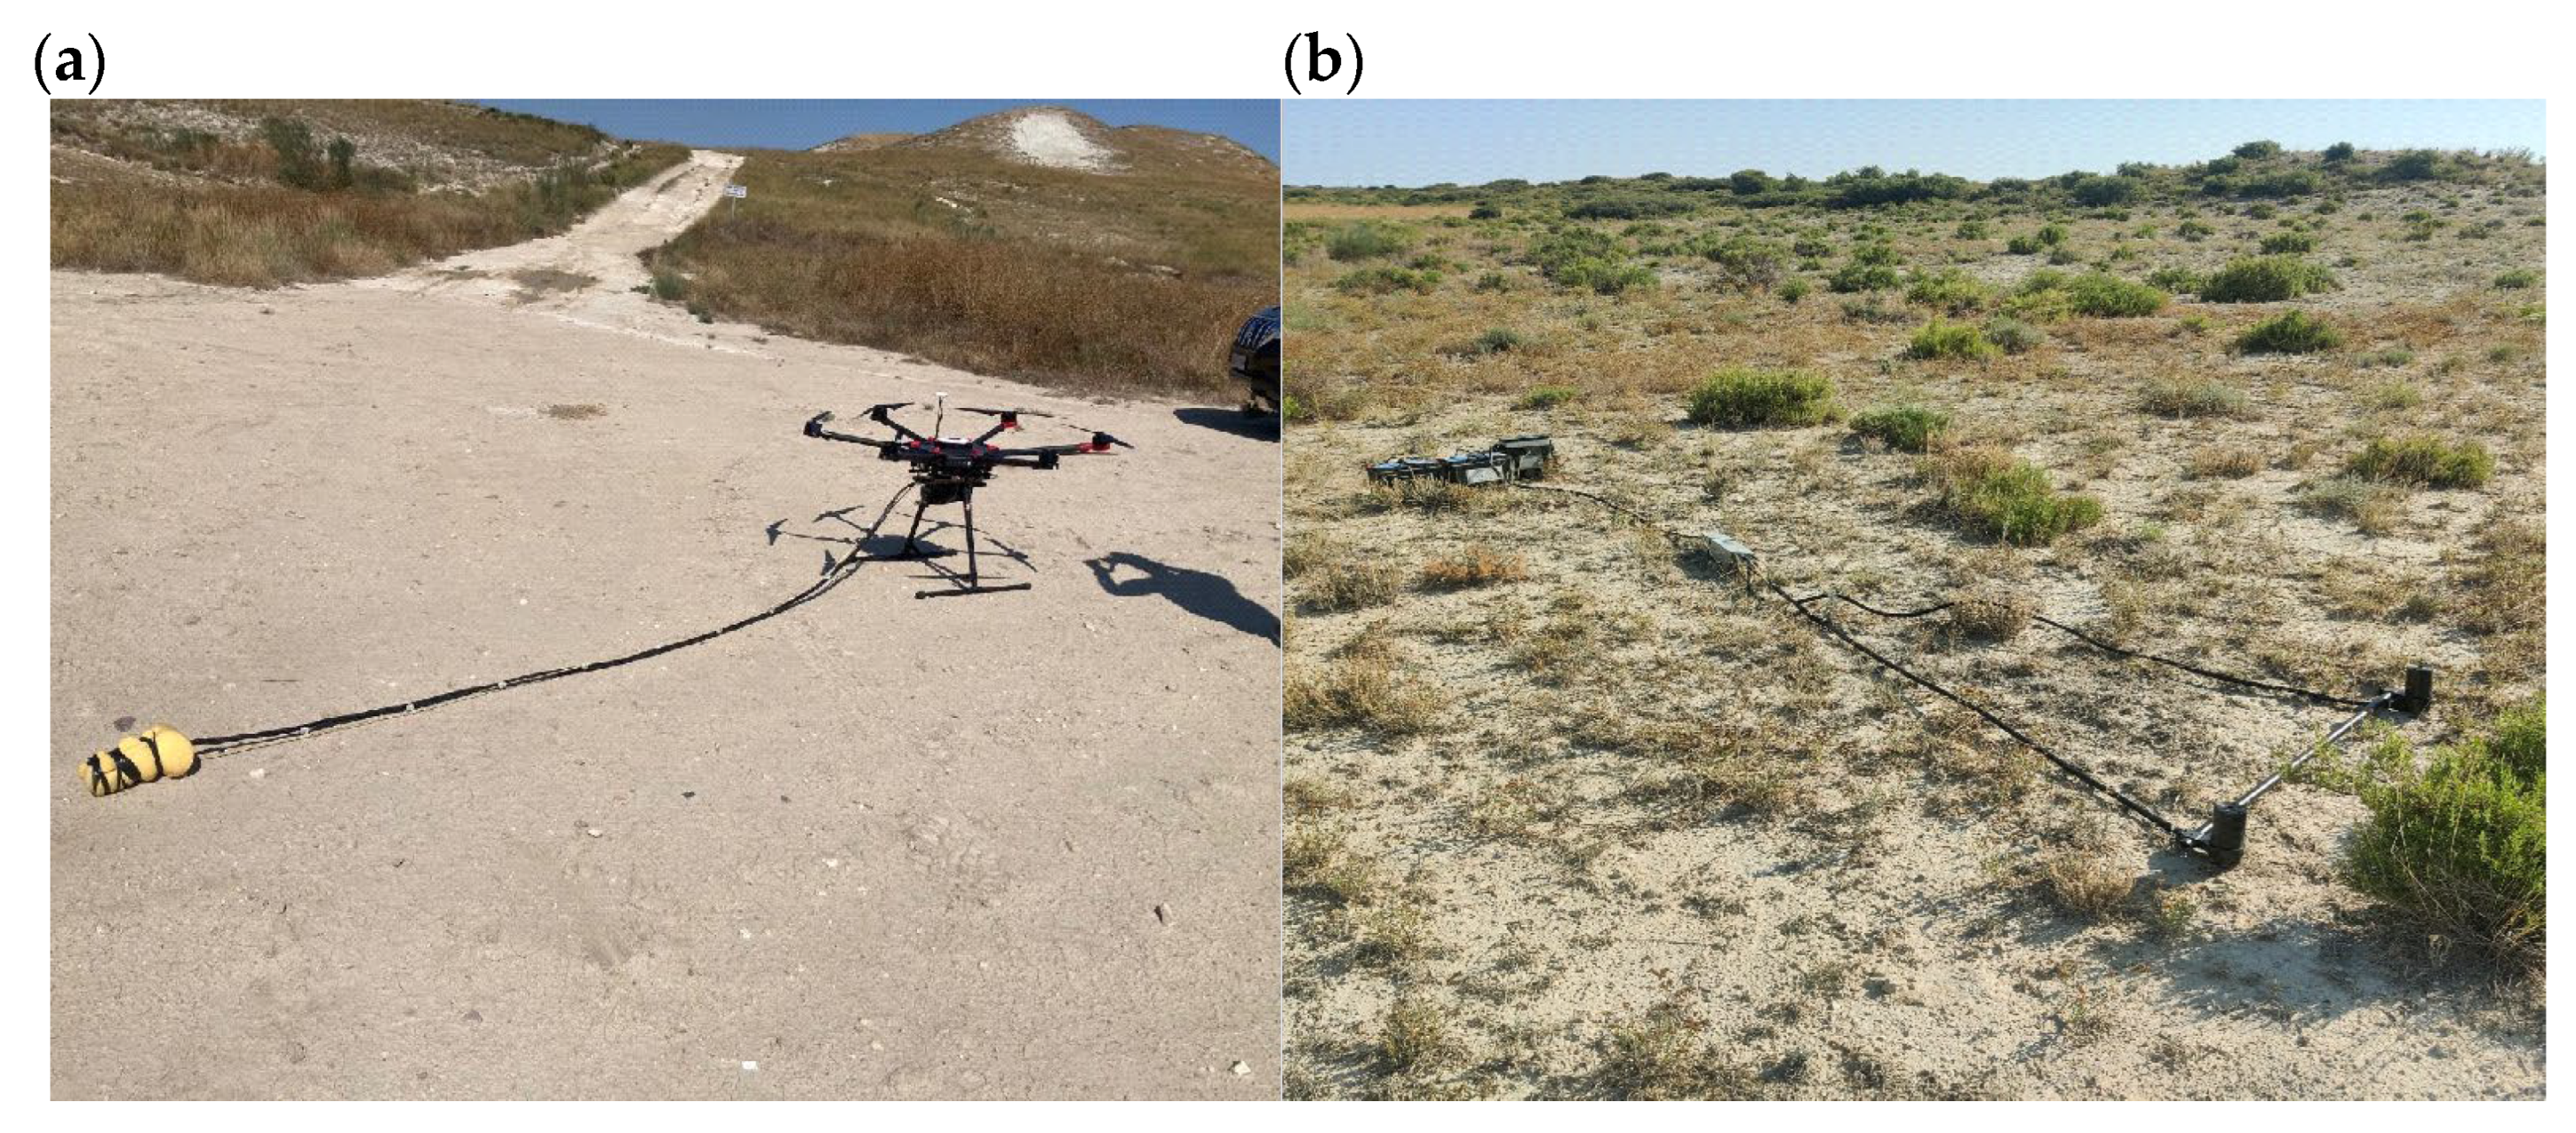
The aeromagnetic survey was carried out using a custom-configured hexacopter aerial drone (DJI Matrice 600, DJI, Shenzhen, China) equipped with a GEM GSMP-35U proton-precession magnetometer suspended 2.5 m below the airframe on a non-magnetic carbon-fibre arm to minimise platform-induced magnetic interference. During all flight operations, the hexacopter’s yaw (heading) was maintained in a fixed orientation aligned with the flight-line direction to minimise heading-dependent magnetic errors, particularly critical for orientation-sensitive sensors. This configuration, combined with the suspended sensor geometry, effectively reduced platform-induced magnetic interference to <2 nT, well below target anomaly amplitudes. A composite figure illustrating the installation is shown in Figure 3.
Figure 3.
Field installation of the two magnetometer systems used in this study. (a) GEM GSMP-35U airborne magnetometer deployed in a towed-bird configuration beneath the hexacopter aerial drone for aeromagnetic surveying. (b) GEM GSMP-40 ground magnetometer arranged in a horizontal configuration for base-station and ground-reference magnetic measurements.
A ground-based reference station equipped with a GEM GSMP-40 potassium magnetometer was deployed in a magnetically quiet location outside the impact area to continuously record temporal geomagnetic variations, enabling subsequent diurnal correction of airborne data.
Complete technical specifications of the aerial drone platform and both magnetometer systems are provided in Table 2. Key operational parameters include maximum flight endurance of 40 min with 2 kg payload, magnetometer sensitivity of 0.0002 nT @ 1 Hz, and configurable sampling rates up to 20 Hz. Both sensors were factory-calibrated prior to the field campaign.
Table 2.
Technical specifications of the hexacopter aerial drone, the GEM GSMP-35U airborne magnetometer, and the GEM GSMP-40 base-station magnetometer.
2.4. Flight Planning and Aeromagnetic Survey
Data acquisition was planned for stable meteorological conditions to minimise atmospheric interference. Two consecutive aeromagnetic surveys were designed to be performed over the same area at different flight heights (7 m and 2 m above ground level) to systematically evaluate the influence of sensor–target distance on the magnetic response of buried UXO surrogates and enable direct comparison of detection performance, signal-to-noise ratios, and anomaly morphology.
Both surveys were designed along a regular grid of parallel flight lines with 1 m spacing, oriented parallel to the perimeter firebreak delimiting the test area. This configuration was selected to maximise area coverage while ensuring sufficiently dense spatial sampling for detecting small-scale magnetic anomalies associated with UXO.
Flight planning incorporated a high-resolution DTM to generate terrain-following flight paths, maintaining constant heights of 7 m and 2 m above ground level. This approach is critical for ensuring consistent sensor–target distances in undulating terrain and for minimising collision risk. The planned flight speed was 5 m/s with magnetometer sampling configured at 20 Hz, yielding a theoretical along-track spacing of approximately 0.25 m between successive measurements.
The survey design covered 0.53 ha (5300 m2) in the F-23 perimeter firebreak sector using 42 parallel flight lines (total trajectory length ~21 km). All positional data were configured to be recorded in the WGS84/UTM zone 30N reference system to ensure accurate georeferencing for subsequent ground-truthing operations.
The planned sampling density (~0.25 m along-line × 1 m cross-line spacing) was selected as appropriate for resolving decametric-scale anomalies associated with metallic cylindrical objects in the 60–155 mm calibre range [4,8].
The main technical parameters of the aeromagnetic surveys are compiled in Table 3.
Table 3.
Technical parameters of the aeromagnetic survey conducted at the CENAD San Gregorio.
The total surveyed surface was 0.53 ha (5300 m2) in the F-23 perimeter firebreak sector, covered by 42 parallel flight lines with 1 m spacing. The aerial drone maintained a constant ground speed of 5 m/s in both campaigns, with the magnetometer sampling at 20 Hz, corresponding to one measurement every 50 ms and an along-line spacing of approximately 0.25 m between successive points. The two flight heights (7 m and 2 m) resulted in identical numbers of recorded measurements (26,771 points per survey), for a combined total of 53,542 data points. Effective flight time for both surveys was less than one hour. All positional data were recorded in the WGS84/UTM zone 30N reference system.
The chosen sampling density (~0.25 m along-line spacing and 1 m line spacing) is appropriate for resolving decametric-scale anomalies associated with metallic cylindrical objects in the 60–155 mm calibre range. The stable meteorological conditions and low wind speeds during the survey contributed to flight stability and sensor performance, minimising attitude variations and platform-induced noise [4,8].
2.5. Rationale of the Acquisition Strategy
The acquisition parameters were selected to guarantee adequate spatial sampling for magnetic detection. The 20 Hz sampling rate combined with a 5 m/s flight speed produced an effective along-track spacing of ~0.25 m, sufficient to resolve short-wavelength anomalies generated by small ferromagnetic objects. The 1 m flight-line spacing ensured lateral oversampling, while the two flight heights (2 m and 7 m) allowed quantification of the cubic attenuation of magnetic amplitude (1/r3). These acquisition choices were technically motivated to maximise the signal-to-noise ratio, minimise aliasing, and provide suitable input data.
2.6. Processing and Interpretation
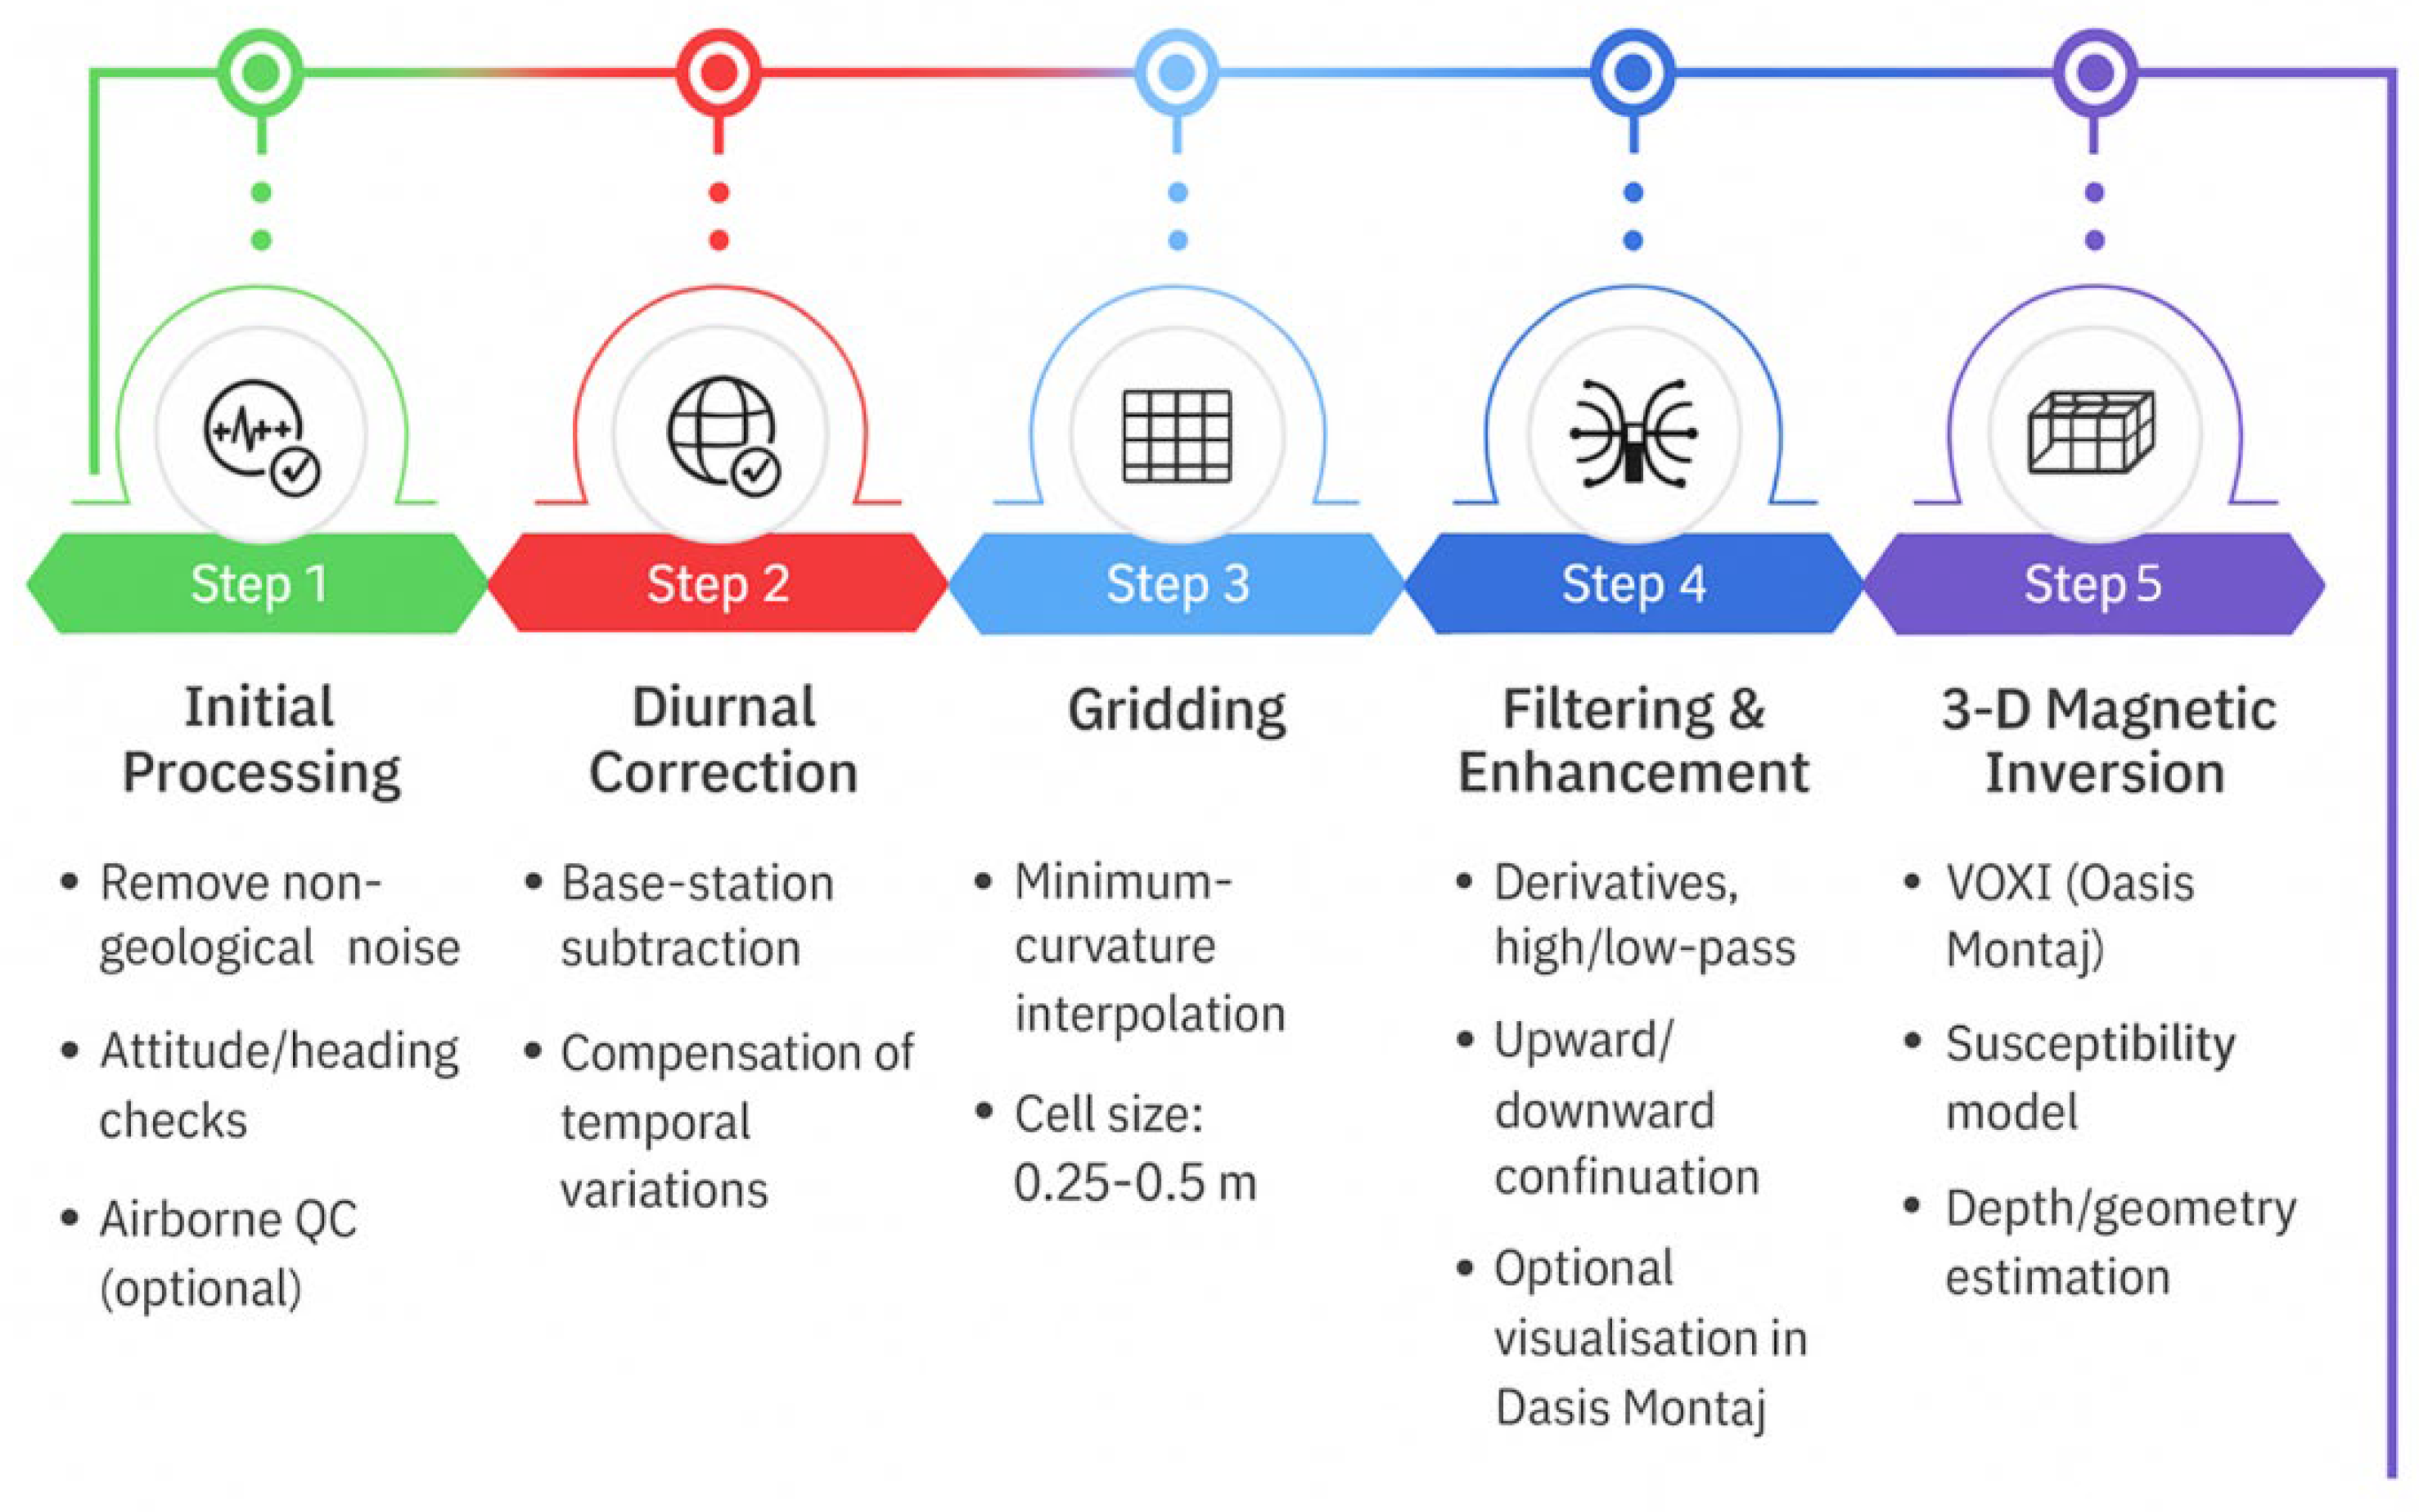
The magnetic-data processing followed a structured workflow designed to enhance weak anomalies in cluttered environments. The processing sequence consists of six main stages:
- Pre-processing and quality control: removal of spikes associated with take-off and landing, attitude-change artefacts, and platform-induced disturbances. These steps were performed using the Airborne Quality Control module in Oasis Montaj (Seequent, Oasis montaj 2025.1).
- Diurnal correction: subtraction of the base-station time series to compensate for temporal geomagnetic variations.
- Gridding: minimum-curvature interpolation using a cell size of 0.25–0.5 m, consistent with the acquisition spacing.
- Noise filtering and signal enhancement: application of directional derivatives, high-pass and low-pass filters, and upward/downward continuation to suppress regional magnetic trends and emphasise short-wavelength responses associated with near-surface ferromagnetic sources. All these operations can optionally be performed within the Oasis Montaj environment, allowing users to visualise the results and familiarise themselves with the behaviour of the magnetic field.
- Spectral transformations:
- Reduction to the Pole (RTP) to centre dipolar anomalies given the local inclination.
- Analytic Signal to obtain amplitude-only gradients independent of magnetisation direction and to highlight compact sources.
- Three-dimensional magnetic inversion: depth-constrained magnetic-susceptibility inversion performed using the VOXI Earth Modelling module in Oasis Montaj. The inversion enabling the estimation of subsurface susceptibility distributions and the derivation of the geometry and depth of the ferromagnetic sources. This 3D modelling step provides a volumetric interpretation that complements the 2D maps and enhances understanding of the spatial characteristics of the detected anomalies.
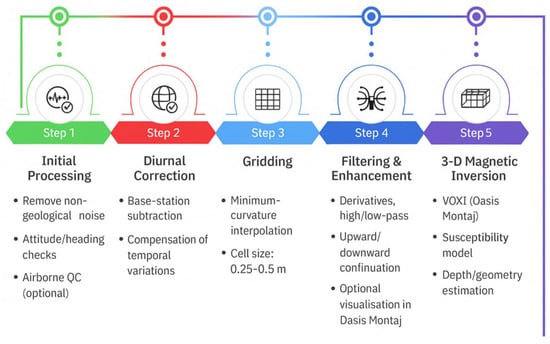
This processing chain represents the central methodological contribution of the study, enabling the identification of 2–18 nT anomalies despite intense ferromagnetic noise. Once the aerial drone magnetometry campaign was completed, the processing and interpretation workflow was applied in detail as described below (Figure 4).
Figure 4.
Processing and interpretation methodology developed for the detection of UXOs.
The raw magnetic data acquired by the aerial drone-mounted magnetometer underwent an initial quality-control and cleaning stage to ensure the integrity of the subsequent analysis (Figure 4, Step 1). Non-geological noise was first removed, including transient disturbances produced during take-off, landing, and platform manoeuvres such as sharp turns or velocity changes. These unstable segments were identified by examining the platform attitude logs and by detecting inconsistencies in the magnetic signal. Additional checks for heading errors, sensor saturation, and platform-induced disturbances were carried out using the Airborne Quality Control module in Oasis Montaj.
Diurnal magnetic variations were then corrected using data from a proximal base-station magnetometer (Figure 4, Step 2). The base-station time series was low-pass filtered and subtracted from the aerial drone data to compensate for temporal fluctuations in the Earth’s magnetic field, significantly improving the signal-to-noise ratio.
Following these corrections, the magnetic data were interpolated into a regular 2D grid using the minimum-curvature algorithm implemented in Oasis Montaj (Figure 4, Step 3). An optimised cell size between 0.25 and 0.5 m was selected according to the acquisition spacing and flying height, ensuring that short-wavelength magnetic features were preserved. From the resulting grid, total-field maps were generated.
To enhance the magnetic signature of potential ferromagnetic targets and remove directional artefacts, a multi-stage noise-filtering workflow was applied (Figure 4, Step 4). First, heading-related striping artefacts aligned with flight-line direction were identified and removed using directional low-pass filtering, following the decorrugation methodology [27]. This step was essential to eliminate elongated anomalies caused by residual platform magnetisation and attitude variations. Subsequently, spectral analysis of the suspended magnetometer data was performed to identify oscillation frequencies introduced by payload swing. A band-stop filter centred on the dominant oscillation frequency (~1.5 Hz) was applied to attenuate these periodic disturbances, following best practices established by [4,29]. Finally, conventional signal-enhancement operations—including high-pass and low-pass filters, directional derivatives, and upward continuation—were applied to suppress regional magnetic trends while emphasising short-wavelength responses associated with shallow ferromagnetic sources. The effectiveness of each filtering step was visually inspected within Oasis Montaj to ensure anomaly preservation while maximising noise reduction.
Spectral transformations were then applied to improve anomaly interpretability (Figure 4, Step 5). Reduction to the Pole (RTP) was used to centre dipolar anomalies under the local geomagnetic inclination, while the Analytic Signal was computed to obtain amplitude-only gradients independent of magnetisation direction, effectively emphasising compact ferromagnetic bodies.
Finally, three-dimensional magnetic inversion was performed using the VOXI Earth Modelling platform in Oasis Montaj (Figure 4, Step 6). This depth-constrained inversion allowed the estimation of subsurface magnetic susceptibility and provided volumetric models that clarified the geometry and depth of the detected anomalies. The resulting 3D susceptibility distribution complemented the 2D maps and enhanced the spatial interpretation of the magnetic responses.
The final interpretation integrated all processed results with geological context and expert geophysical assessment. Magnetic anomalies were evaluated according to amplitude, dipole geometry, spatial coherence, and estimated depth. Anomalies consistent with compact ferromagnetic cylindrical bodies were identified as priority targets, while weaker or irregular responses likely related to cultural or geological noise were considered potential false positives. The resulting interpretation map provides a reliable, high-resolution framework for guiding ground-truthing and risk-assessment activities.
3. Experimental Results
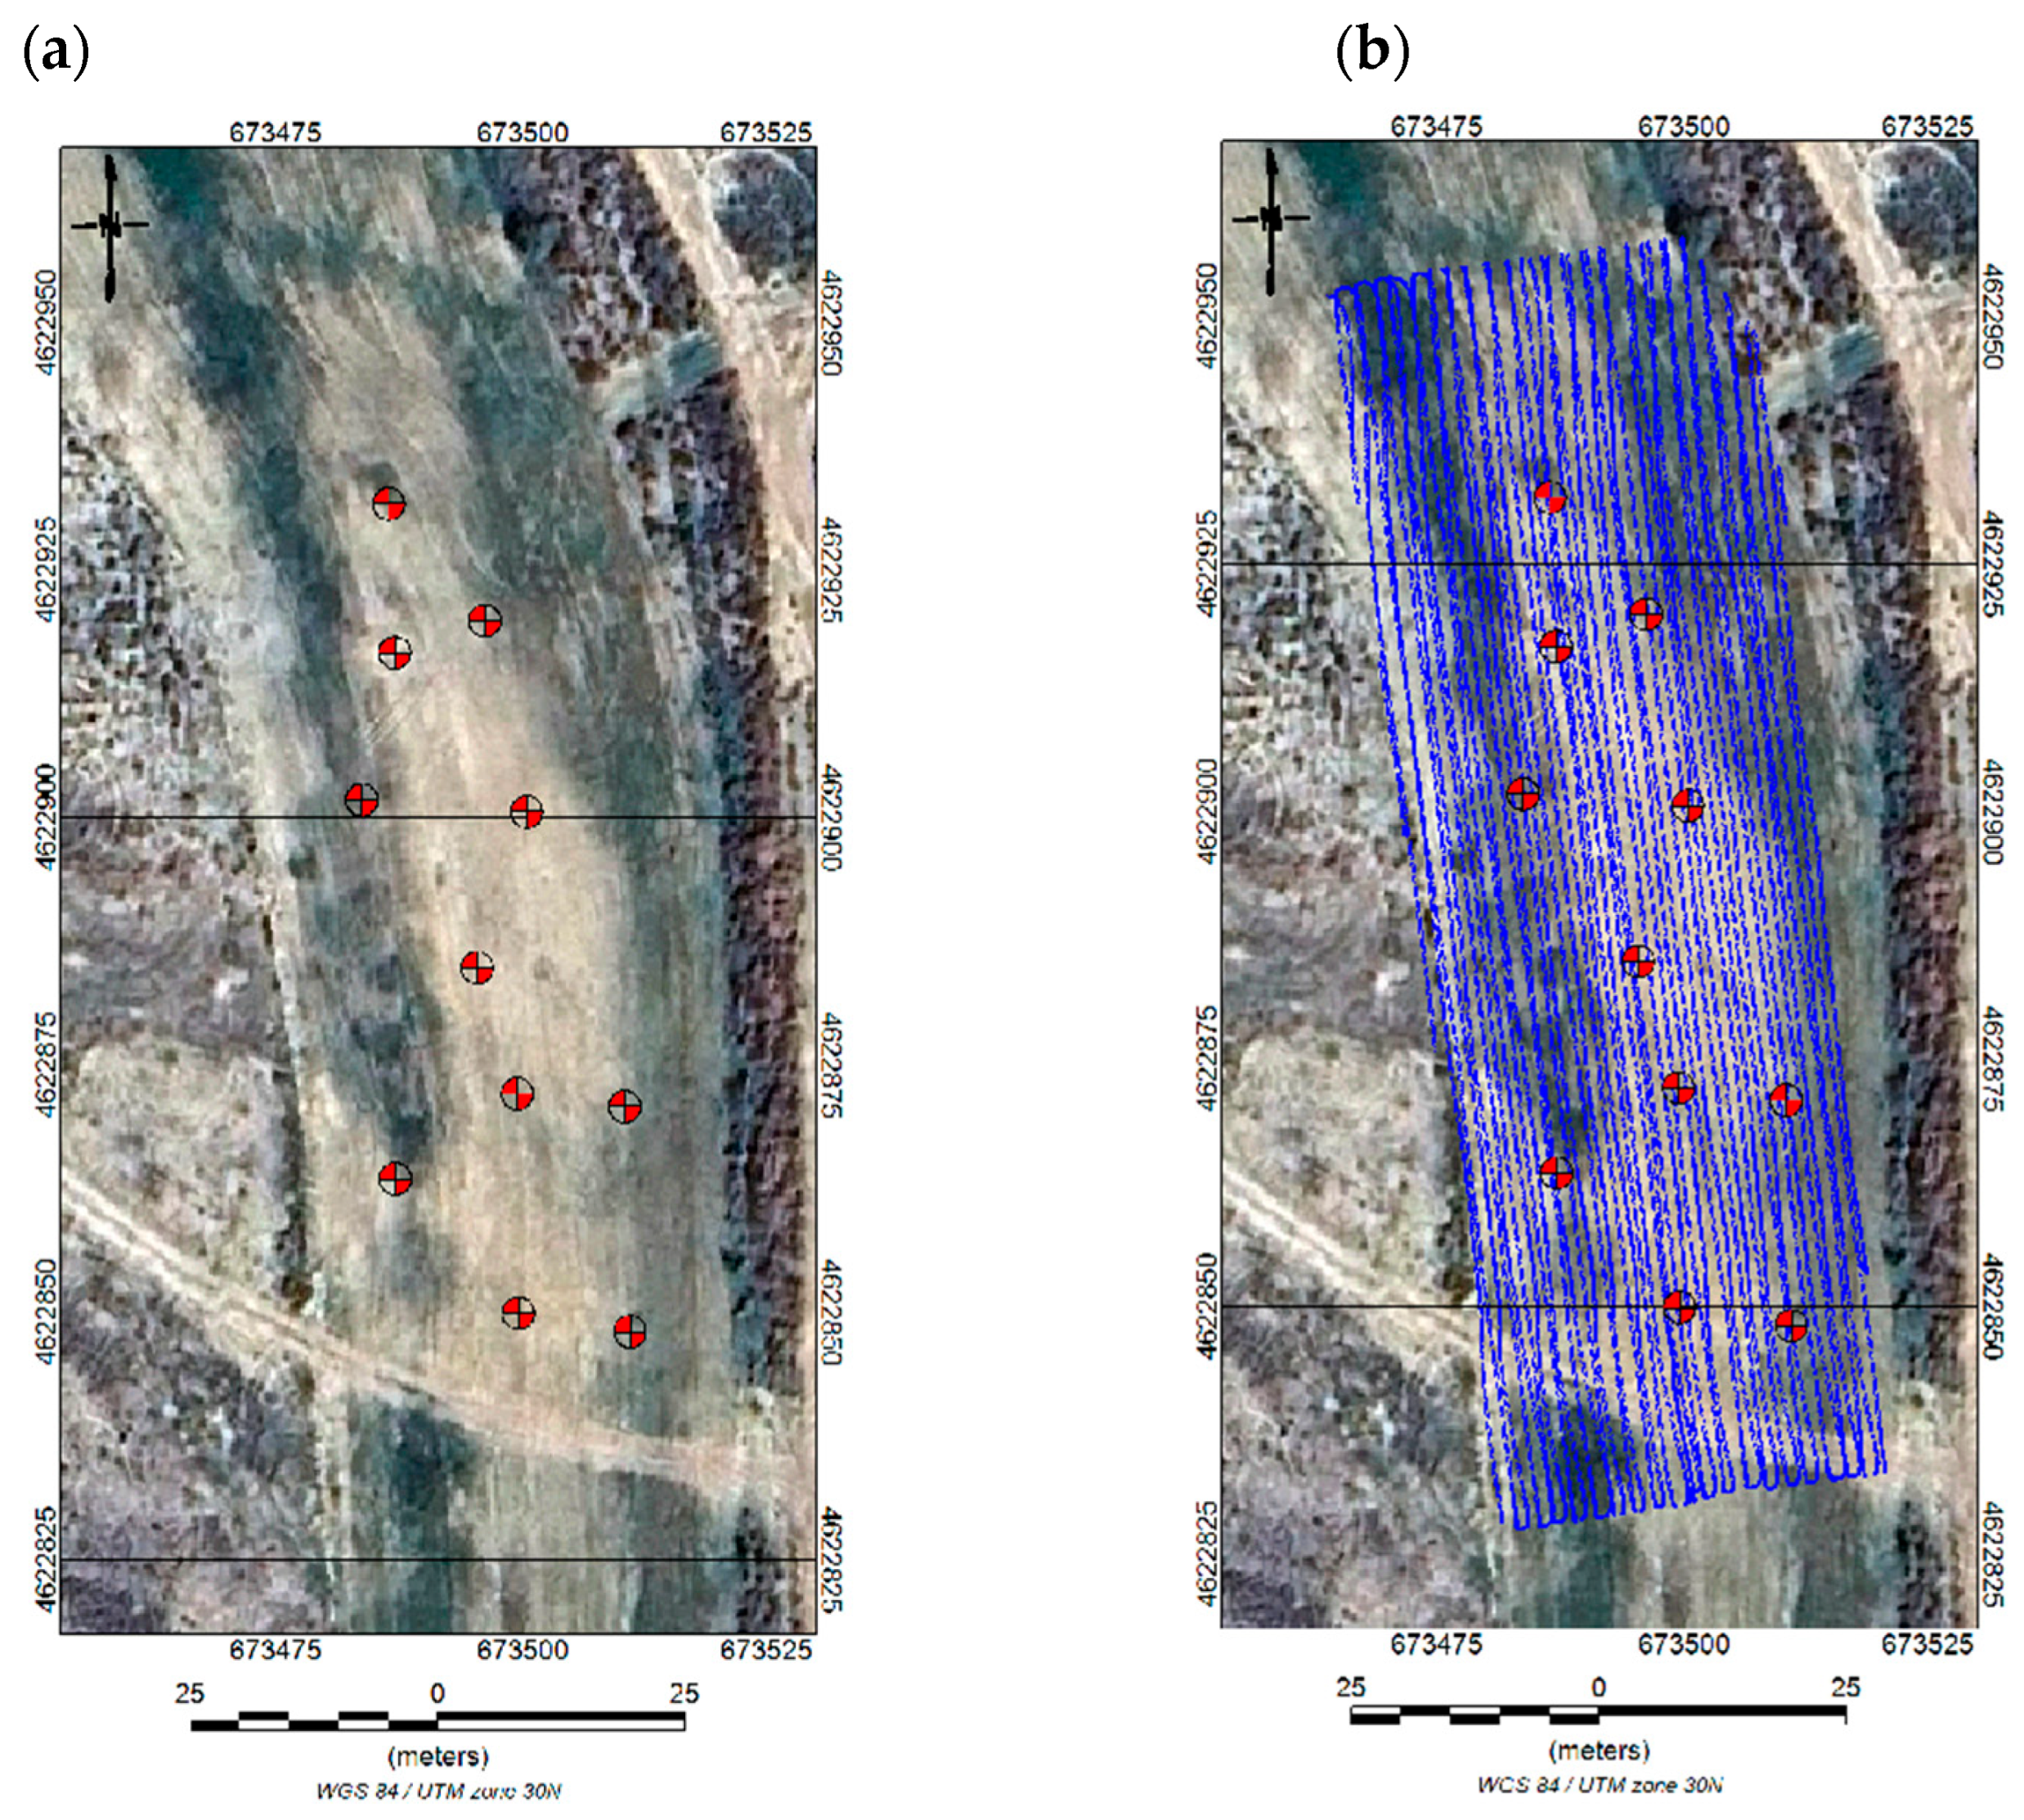
The aeromagnetic survey conducted at the San Gregorio National Training Center (CENAD) clearly revealed the magnetic anomalies associated with the experimentally buried unexploded ordnance (UXO), even within an environment characterised by high levels of ferromagnetic background noise (diurnal variations up to ±3 nT) (Figure 5). The successive processing and interpretation stages are illustrated in the figures presented below, accompanied by an extended discussion to highlight their operational implications.
Figure 5.
Spatial distribution of the buried UXO (a) and layout of the acquisition lines of the aeromagnetic survey (b). Reference system: WGS84/UTM zone 30N.
The application of the full processing workflow significantly improved the clarity of the magnetic anomalies. Diurnal correction reduced temporal noise, the RTP transformation recentred asymmetric dipoles under the local geomagnetic inclination, and the analytic signal isolated compact bodies associated with buried ferromagnetic targets. The combined effect of these processing steps yielded signal-to-noise ratios greater for all targets at the 2 m flight height.
3.1. Survey Execution and Data Quality
The aeromagnetic survey was successfully executed on 14 July 2025 under favourable meteorological conditions, with a mean air temperature of 24 °C and wind speeds consistently below 10 km/h, conditions that proved optimal for sensor stability and flight precision. Both planned surveys (7 m and 2 m heights) were completed over the 0.53 ha test area, following the 42 parallel flight lines with 1 m spacing. The aerial drone maintained the programmed ground speed of 5 m/s throughout both campaigns, with the magnetometer sampling at the configured 20 Hz rate. This resulted in 26,771 georeferenced magnetic measurements per flight height, yielding a combined dataset of 53,542 data points. The effective total flight time for both surveys was less than one hour, demonstrating the operational efficiency of the aerial drone-based approach. The achieved sampling density of approximately 0.25 m along-track spacing and 1 m cross-track spacing provided coverage of ~50 measurement points per hectare, appropriate for detecting the 60–155 mm calibre metallic cylindrical objects buried in the test area.
Post-processing analysis confirmed a geolocation accuracy of approximately 0.5 m (RMSE), dominated by the combined effects of DTM uncertainty and the discrete sampling interval. The stable meteorological conditions during acquisition contributed to minimal attitude variations and reduced platform-induced magnetic noise, as evidenced in the base-station time series (Section 3.2).
Geolocation accuracy was quantitatively assessed by calculating the horizontal offset between DGPS-surveyed burial coordinates (sub-5 cm precision) and the peak positions of magnetic anomalies identified in the analytic signal maps at 2 m height. For each of the eleven ferromagnetic UXO surrogates, the Euclidean distance between the known burial location and the magnetic anomaly maximum was computed. The resulting offsets ranged from 0.31 m to 0.67 m, with a root-mean-square error (RMSE) of 0.48 m. This accuracy is primarily limited by the combined effects of DTM uncertainty (±0.15 m vertical, propagating to ±0.20–0.30 m horizontal depending on local terrain slope), discrete spatial sampling (0.25 m along-track × 1.0 m cross-track), and gridding interpolation. The achieved RMSE of ~0.5 m is sufficient to guide targeted ground excavation operations with high confidence, reducing manual search areas to circles of 1–2 m diameter.
The terrain-following capability enabled by DTM-based flight planning successfully maintained near-constant sensor heights above ground level despite local topographic variations, a critical factor for subsequent quantitative comparison of magnetic anomalies between the two flight campaigns
3.2. Diurnal Correction
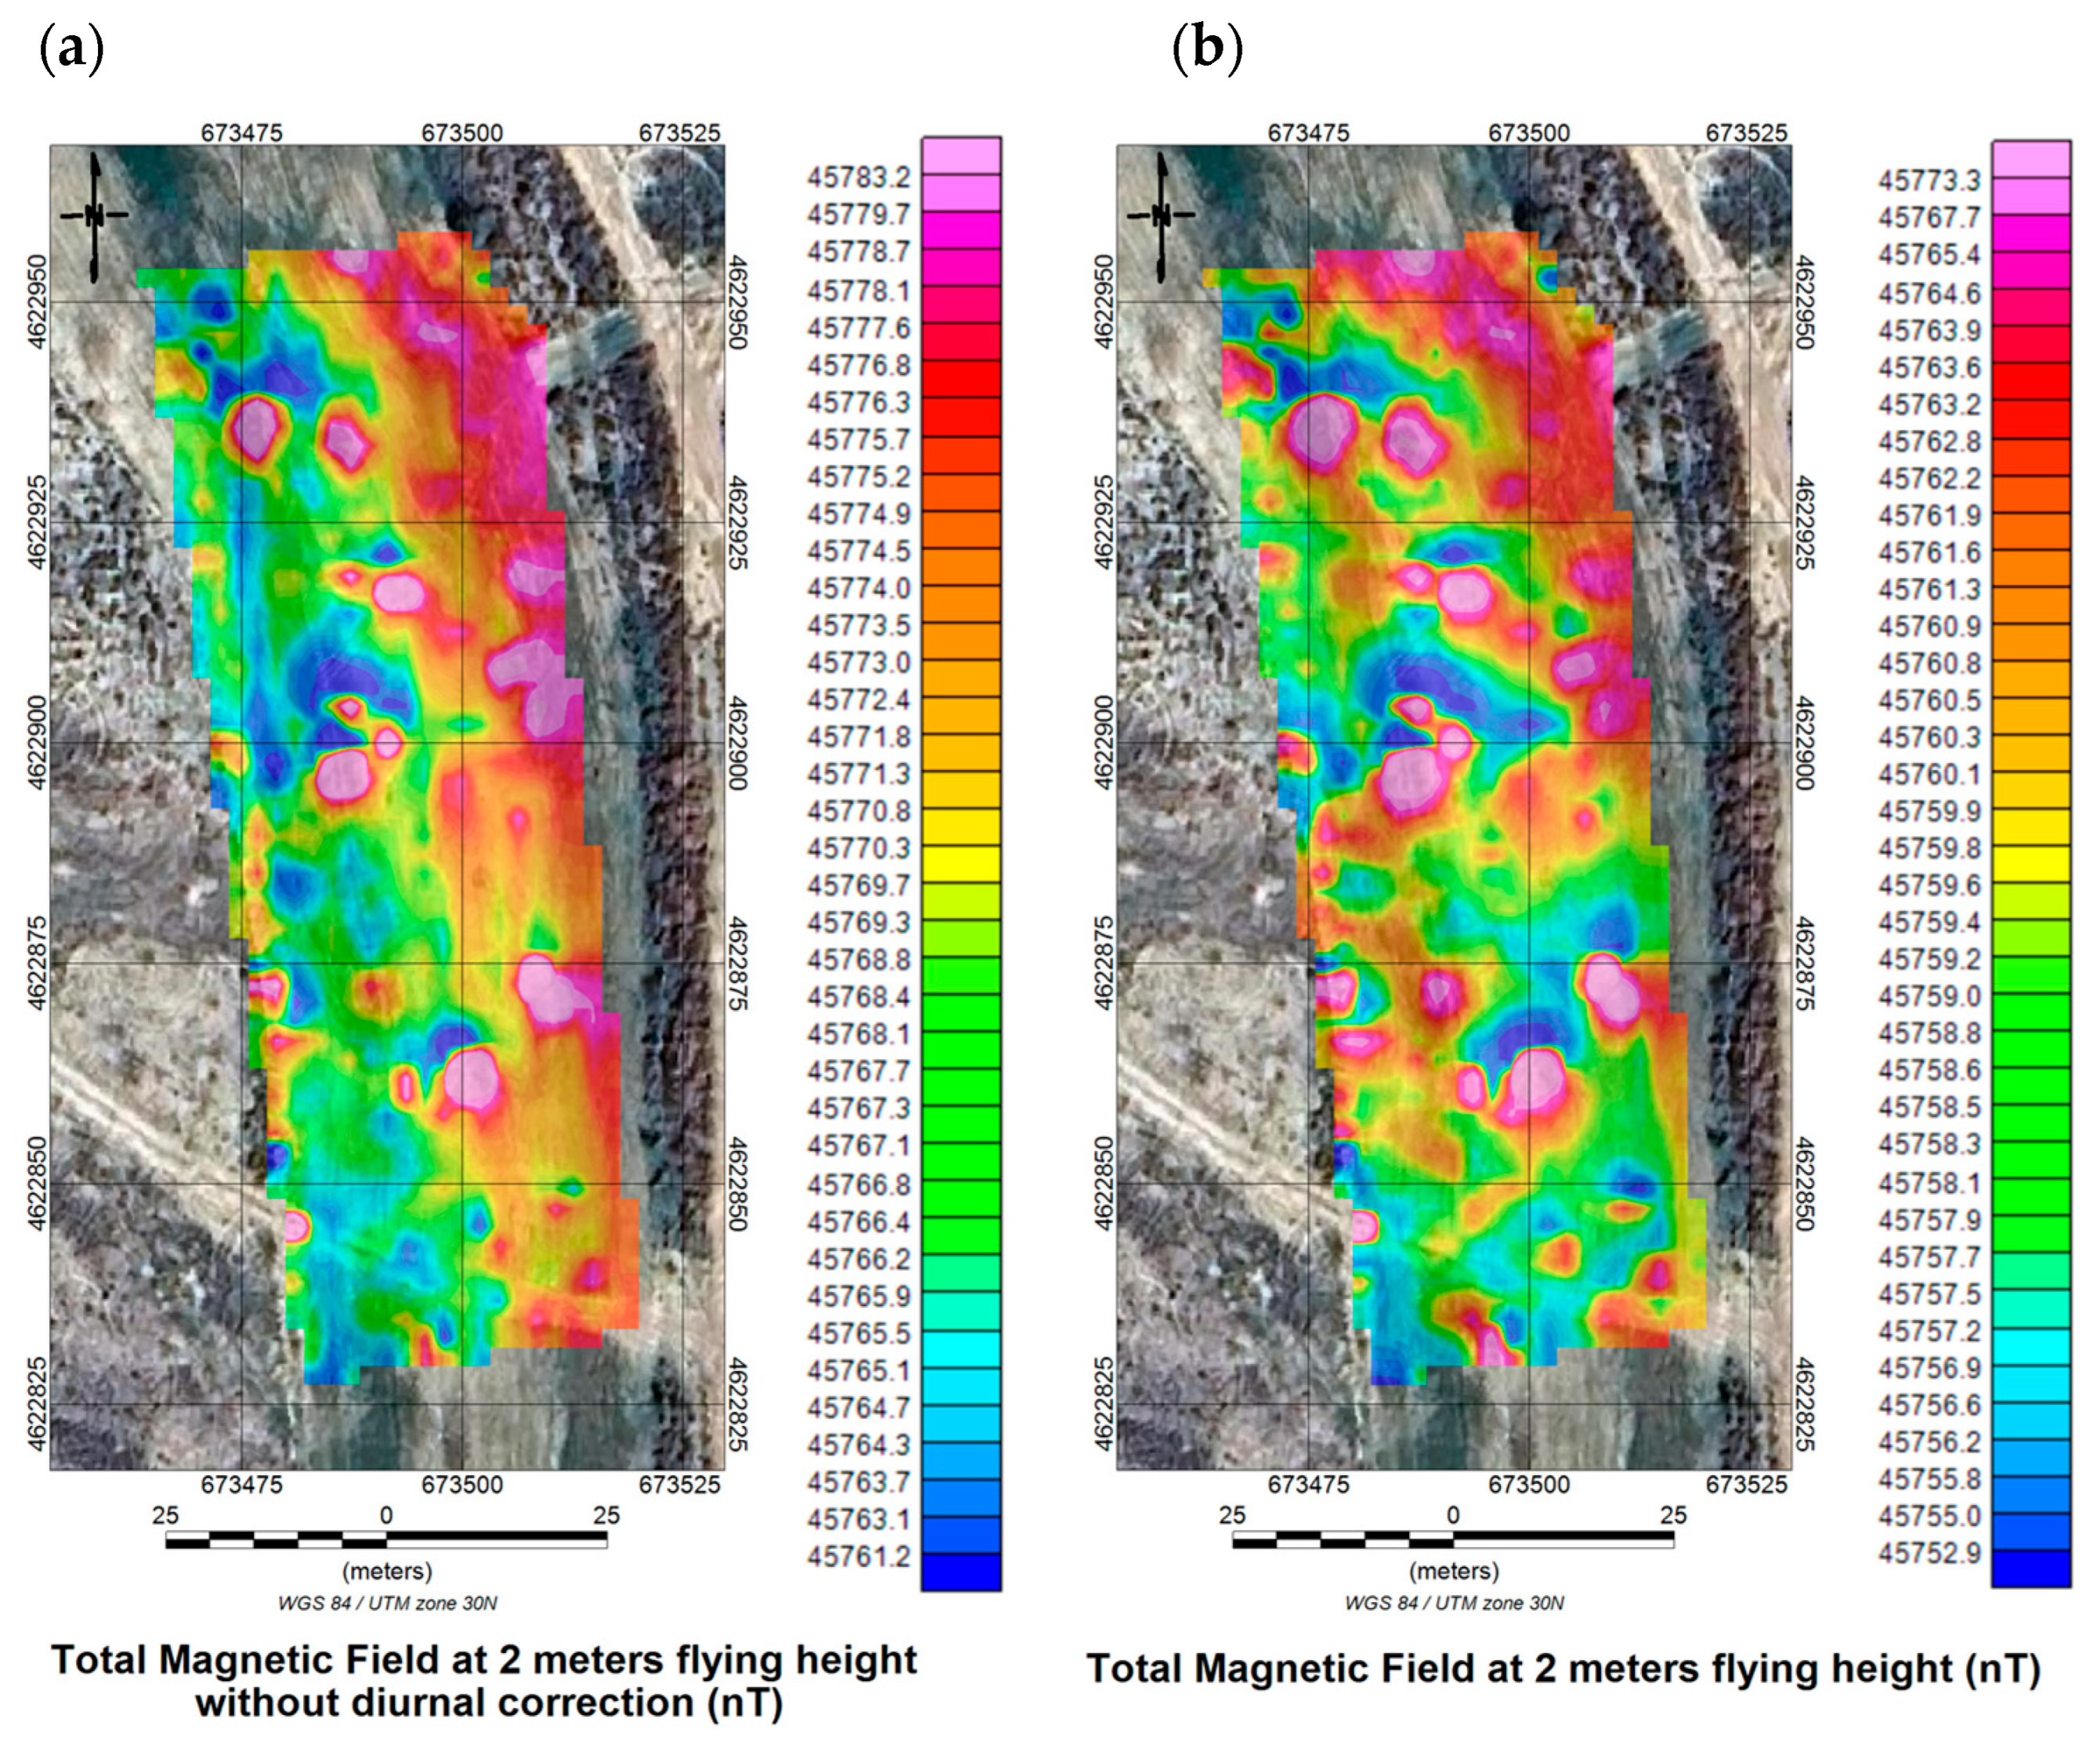
The diurnal variation in the Earth’s magnetic field, driven by ionospheric and solar phenomena, reached amplitudes of up to ±30 nT during data acquisition. Applying the diurnal correction using the potassium base-station magnetometer significantly stabilised the magnetic signal and improved the signal-to-noise ratio—particularly for the 7 m flight, where anomalies were inherently weaker due to the increased sensor–target distance. This correction step is essential in environments affected by temporal magnetic fluctuations, reducing background noise by approximately 30–50% and enabling the detection of subtle anomalies as low as 2 nT. Figure 6 shows the total magnetic field recorded during the 2 m flight (a) and the corrected magnetic field after applying the diurnal correction (b).
Figure 6.
Total magnetic field recorded during the 2 m flight (a) and magnetic field corrected after applying the diurnal correction (b). WGS84/UTM zone 30N (scale in nT).
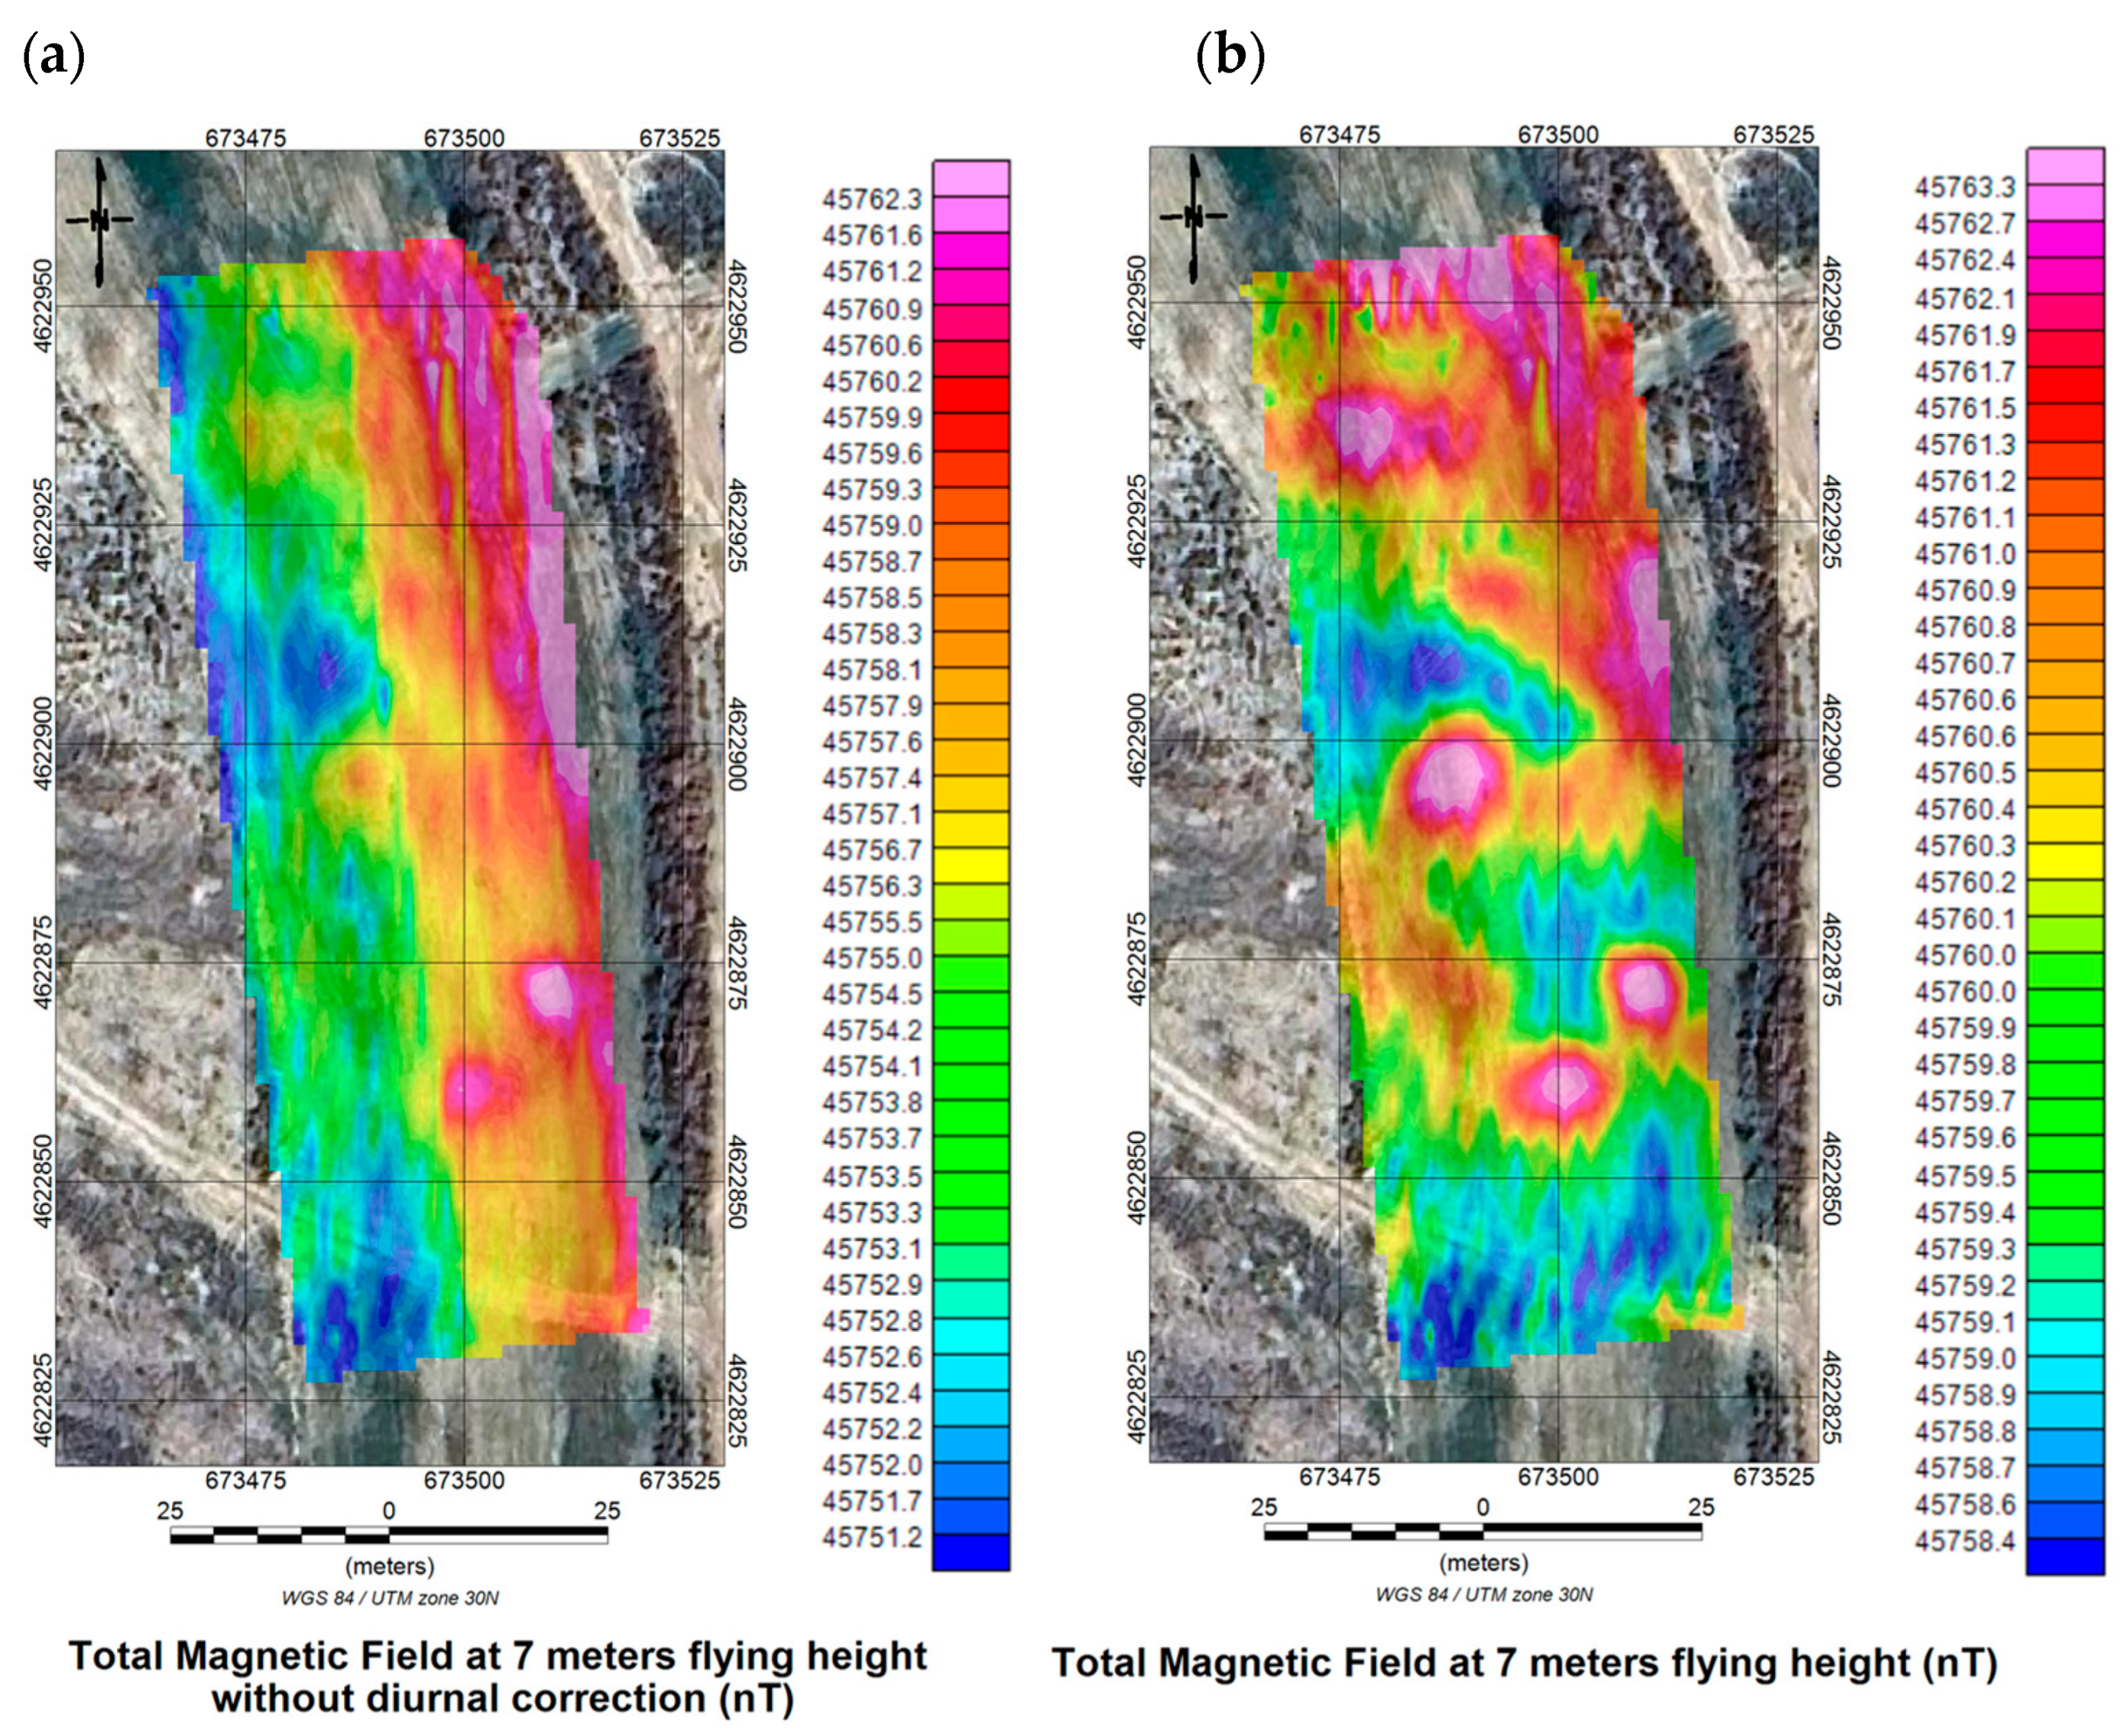
Figure 7 presents the same comparison for the 7 m flight. All maps are displayed in WGS84/UTM Zone 30N with magnetic field intensity in nT.
Figure 7.
Total magnetic field recorded during the 7 m flight (a) and magnetic field corrected after applying the diurnal correction (b). WGS84/UTM zone 30N (scale in nT).
In both cases, a pronounced reduction in background noise is observed (from ±3 nT to <1 nT), together with enhanced definition of localised anomalies associated with the buried UXO. This improvement facilitates the identification of characteristic dipolar peaks. The operational importance of diurnal correction for detecting weak UXO signatures is particularly critical for the 7 m flight, where anomalies are inherently weaker. The relationship between noise reduction and signal-to-noise ratio improvement is enabled by the base-station magnetometer for temporal variation compensation.
3.3. Analysis of the Total Magnetic Field (TMF)
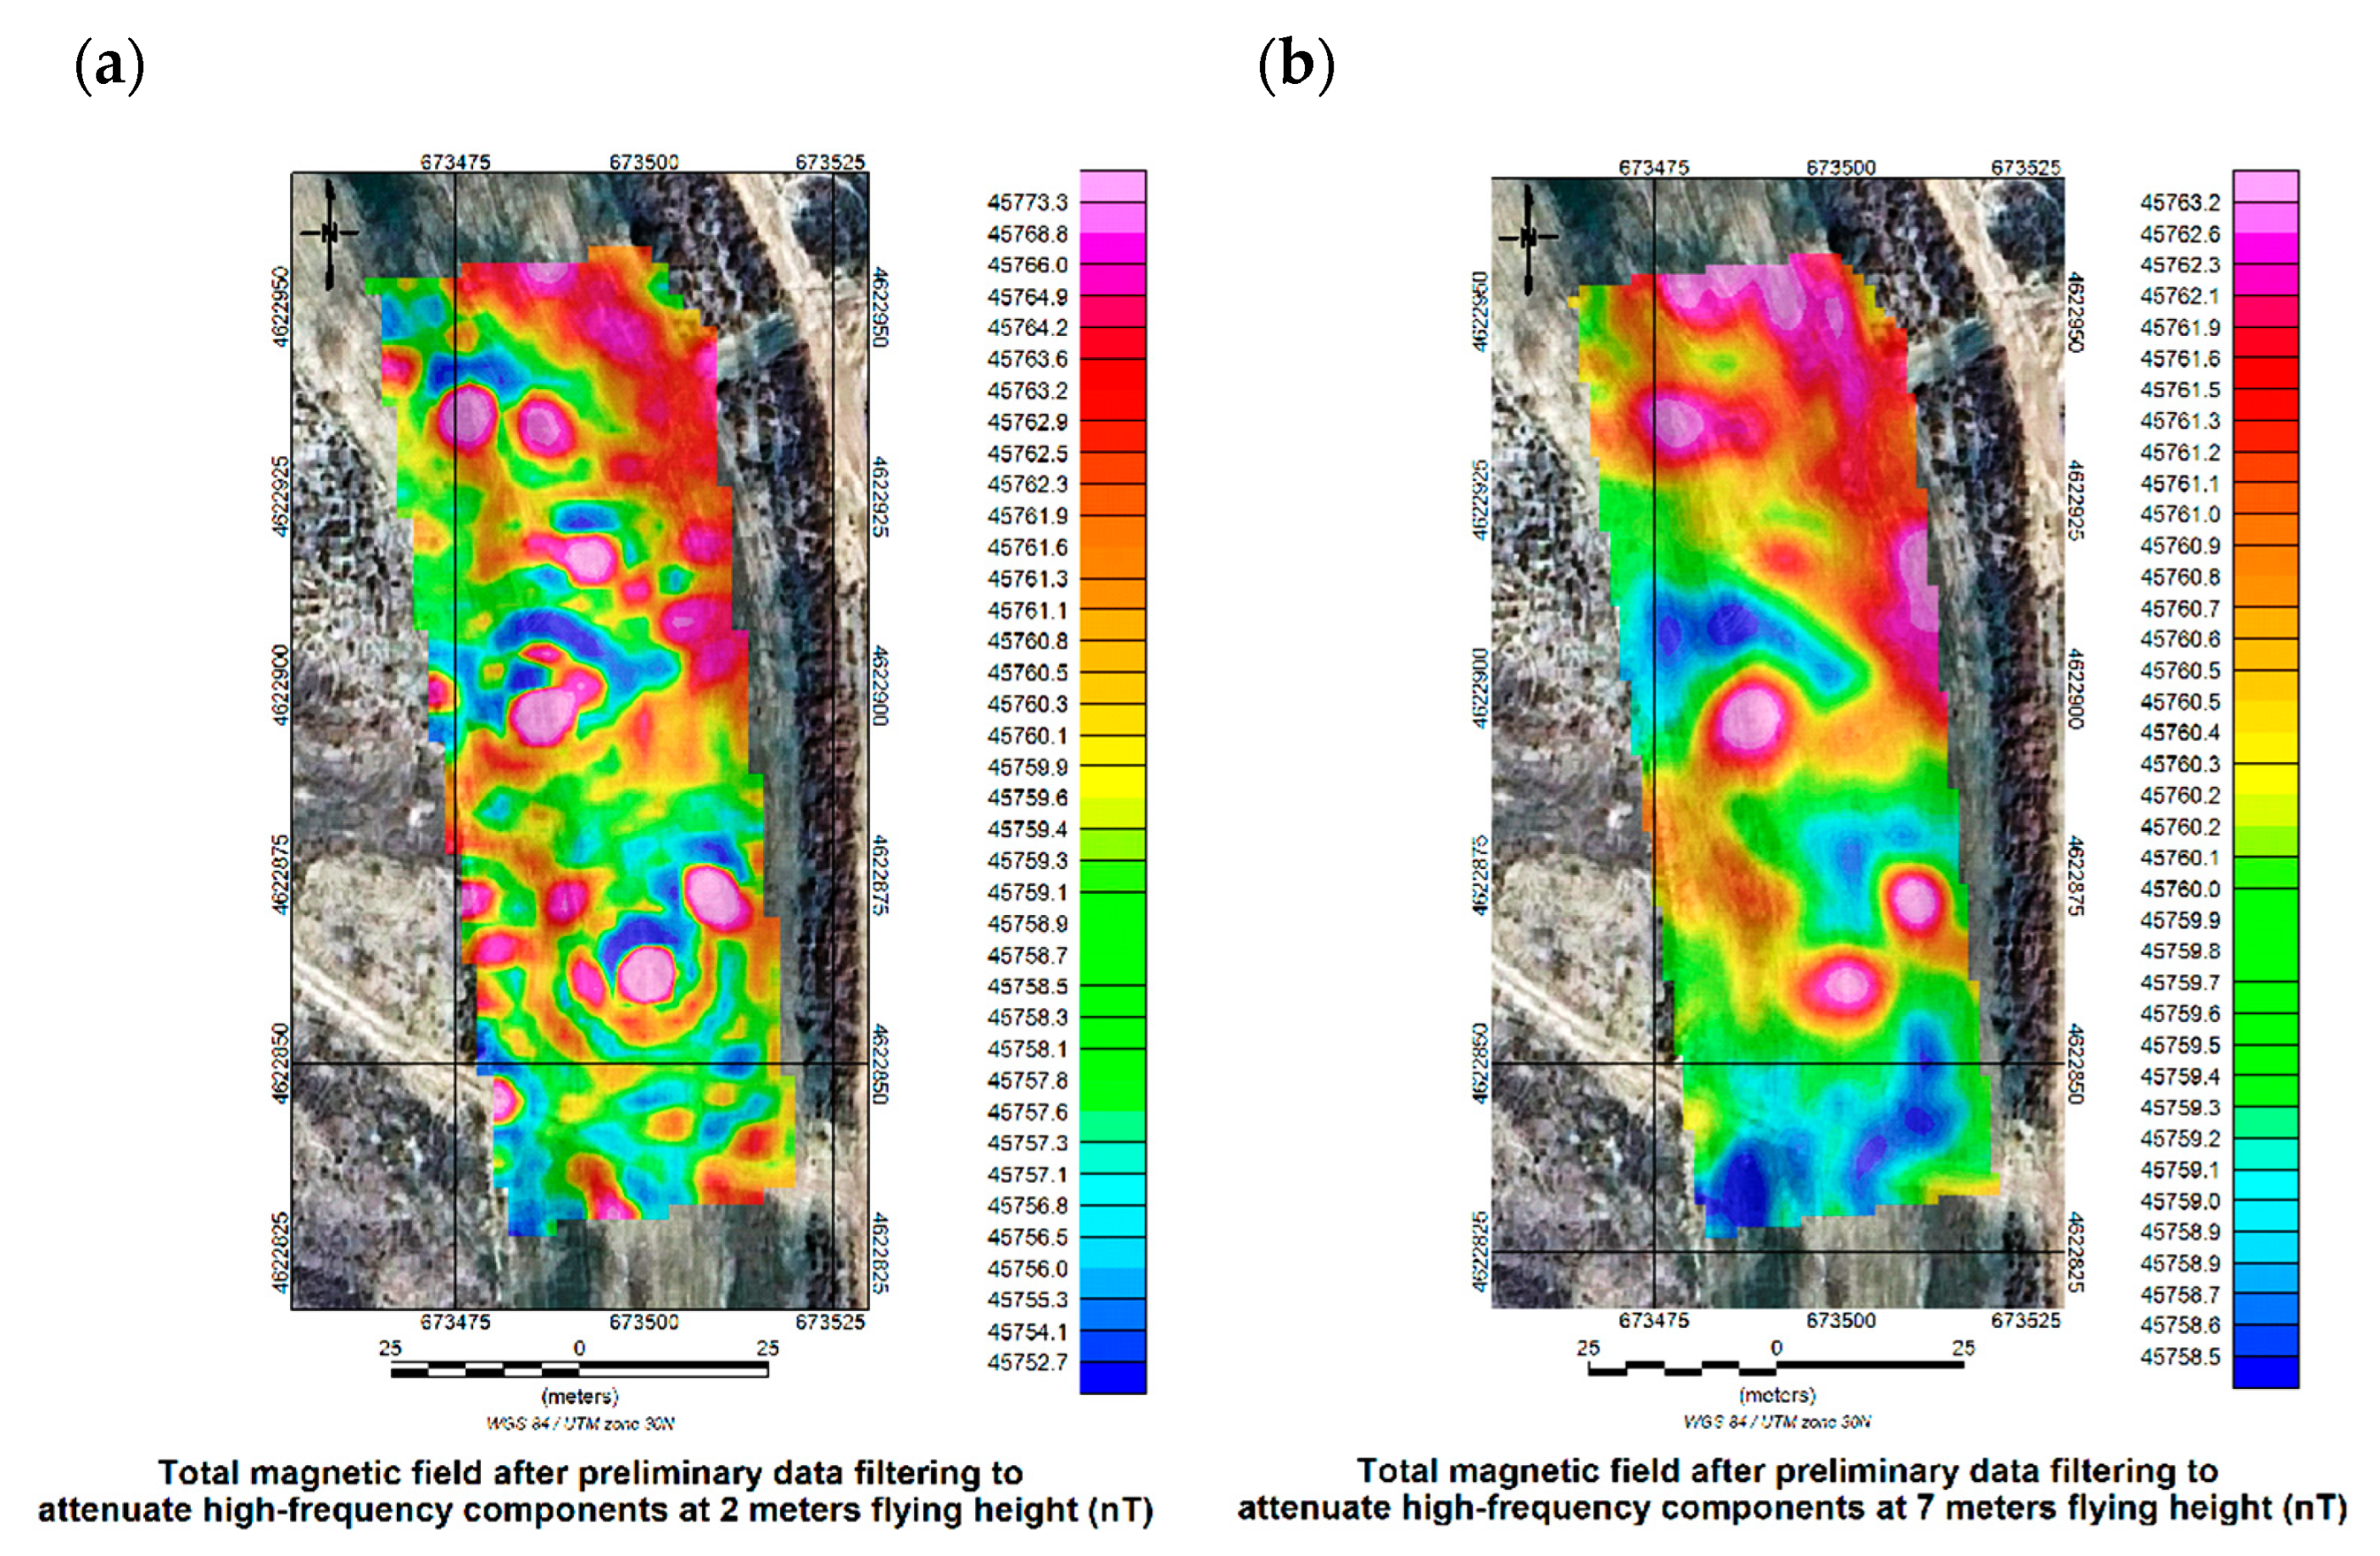
Following preliminary data processing to attenuate high-frequency noise, the corrected and georeferenced TMF maps revealed multiple localised anomalies of varying intensity, with amplitudes ranging from 2 to 18 nT. At 2 m flight height, the anomalies displayed clear dipolar signatures typical of shallow ferromagnetic objects, whereas at 7 m the anomalies appeared attenuated, exhibiting a 40–60% reduction in amplitude. Figure 8 compares the corrected TMF for the 2 m (a) and 7 m (b) flight heights.
Figure 8.
Comparison of the corrected total magnetic field for the 2 m flight (a) and the 7 m flight (b). WGS84/UTM zone 30N (scale in nT).
The spatial positions of these anomalies matched the known coordinates of the buried UXO surrogates, confirming the sensitivity of the system and validating a geolocation accuracy of approximately 0.5 m. All ferromagnetic metallic cylindrical objects were detected, while the plastic anti-tank control projectile produced no detectable magnetic response.
3.4. Reduction to the Pole (RTP)
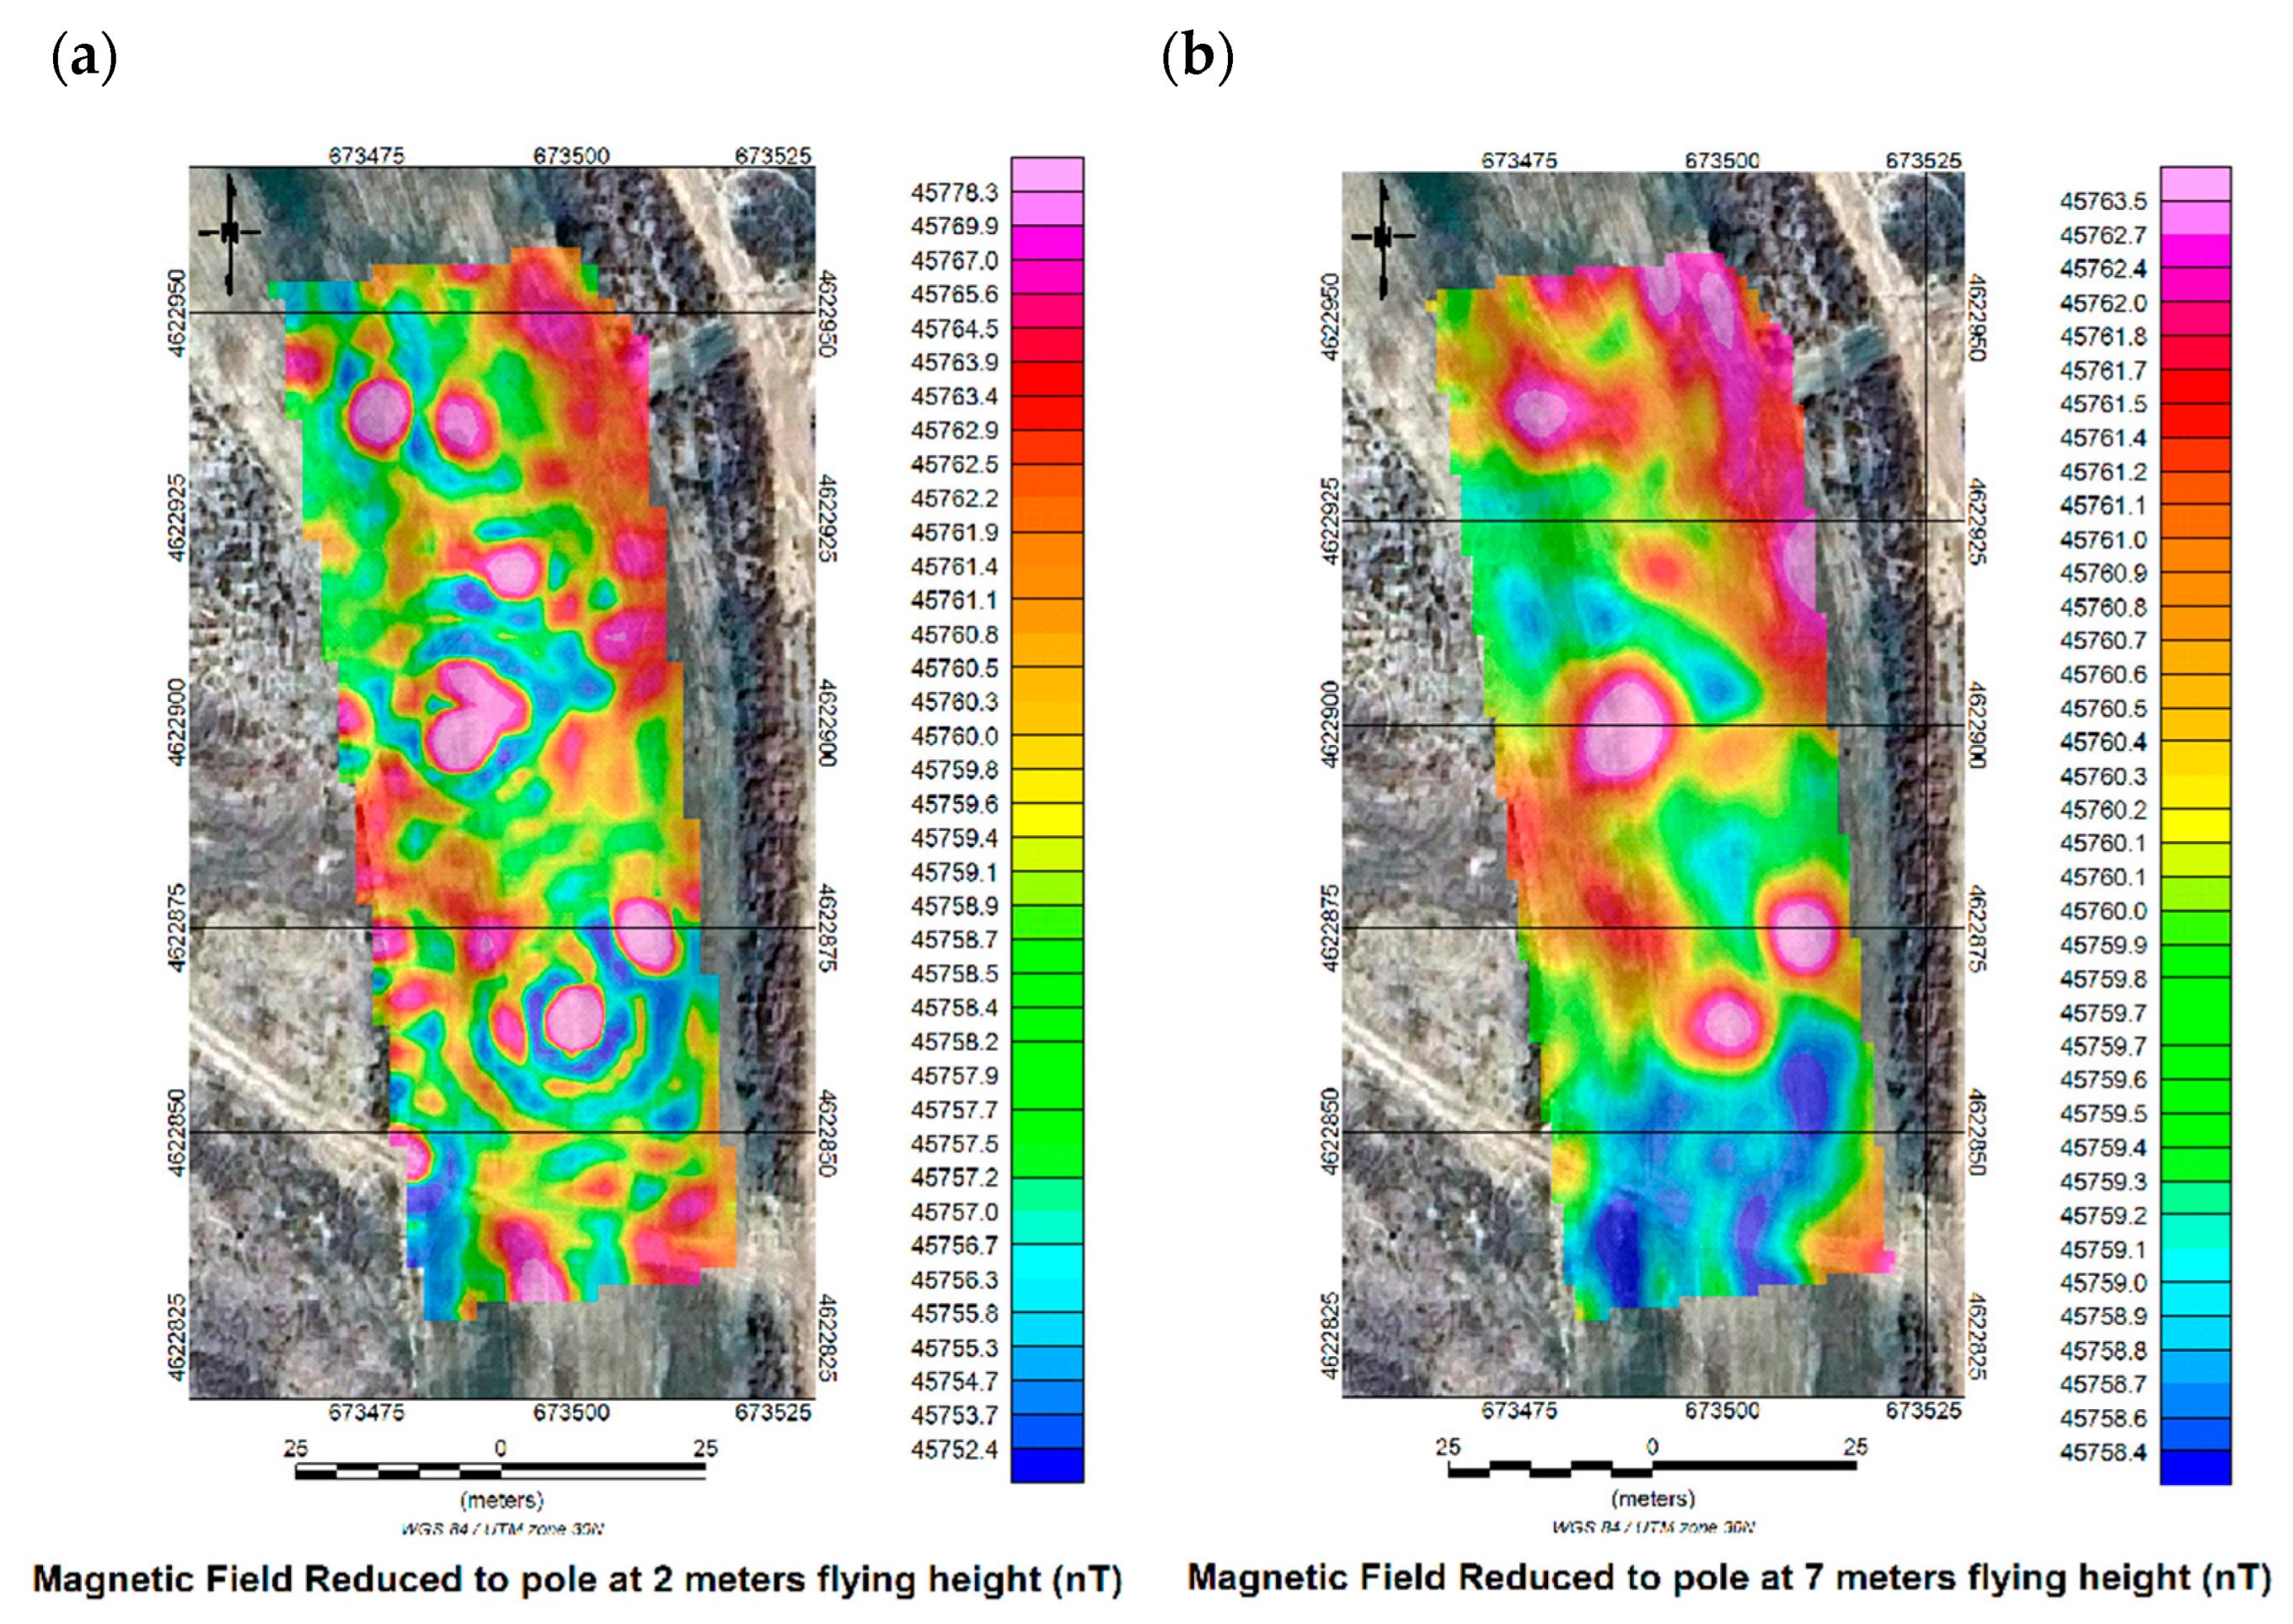
Reduction to the pole (RTP) was applied to transform asymmetrical dipolar anomalies—produced by the local magnetic inclination of ~60°—into centred and more symmetrical responses [36]. This processing step facilitates interpretation by removing directional bias, improving anomaly localisation, and enhancing the distinction between UXO signatures and broader geological noise. RTP is especially useful at mid-latitudes, where dipolar skewing is significant. After RTP transformation, all UXO-related anomalies appeared as compact bodies with maxima centred over the true locations, allowing for a more accurate estimation of their lateral extent (e.g., diameters of 1–2 m for larger metallic cylindrical objects). The method reduced false positives by approximately 20%.
Figure 9 displays the RTP-transformed magnetic field for the 2 m (a) and 7 m (b) flights [37].
Figure 9.
Total magnetic field reduced to the pole for the 2 m flight (a) and the 7 m flight (b). WGS84/UTM zone 30N (scale in nT).
3.5. Vertical Gradient (VG)
The vertical gradient (VG) of the magnetic field was computed to further enhance short-wavelength anomalies associated with shallow ferromagnetic sources and to suppress longer-wavelength regional effects. Vertical derivatives are particularly effective for UXO detection, as they emphasise near-surface magnetic contrasts while attenuating deeper or diffuse background contributions. This property makes the VG especially valuable in cluttered environments such as active military training ranges, where scattered ferromagnetic debris generates broad, low-frequency magnetic noise.
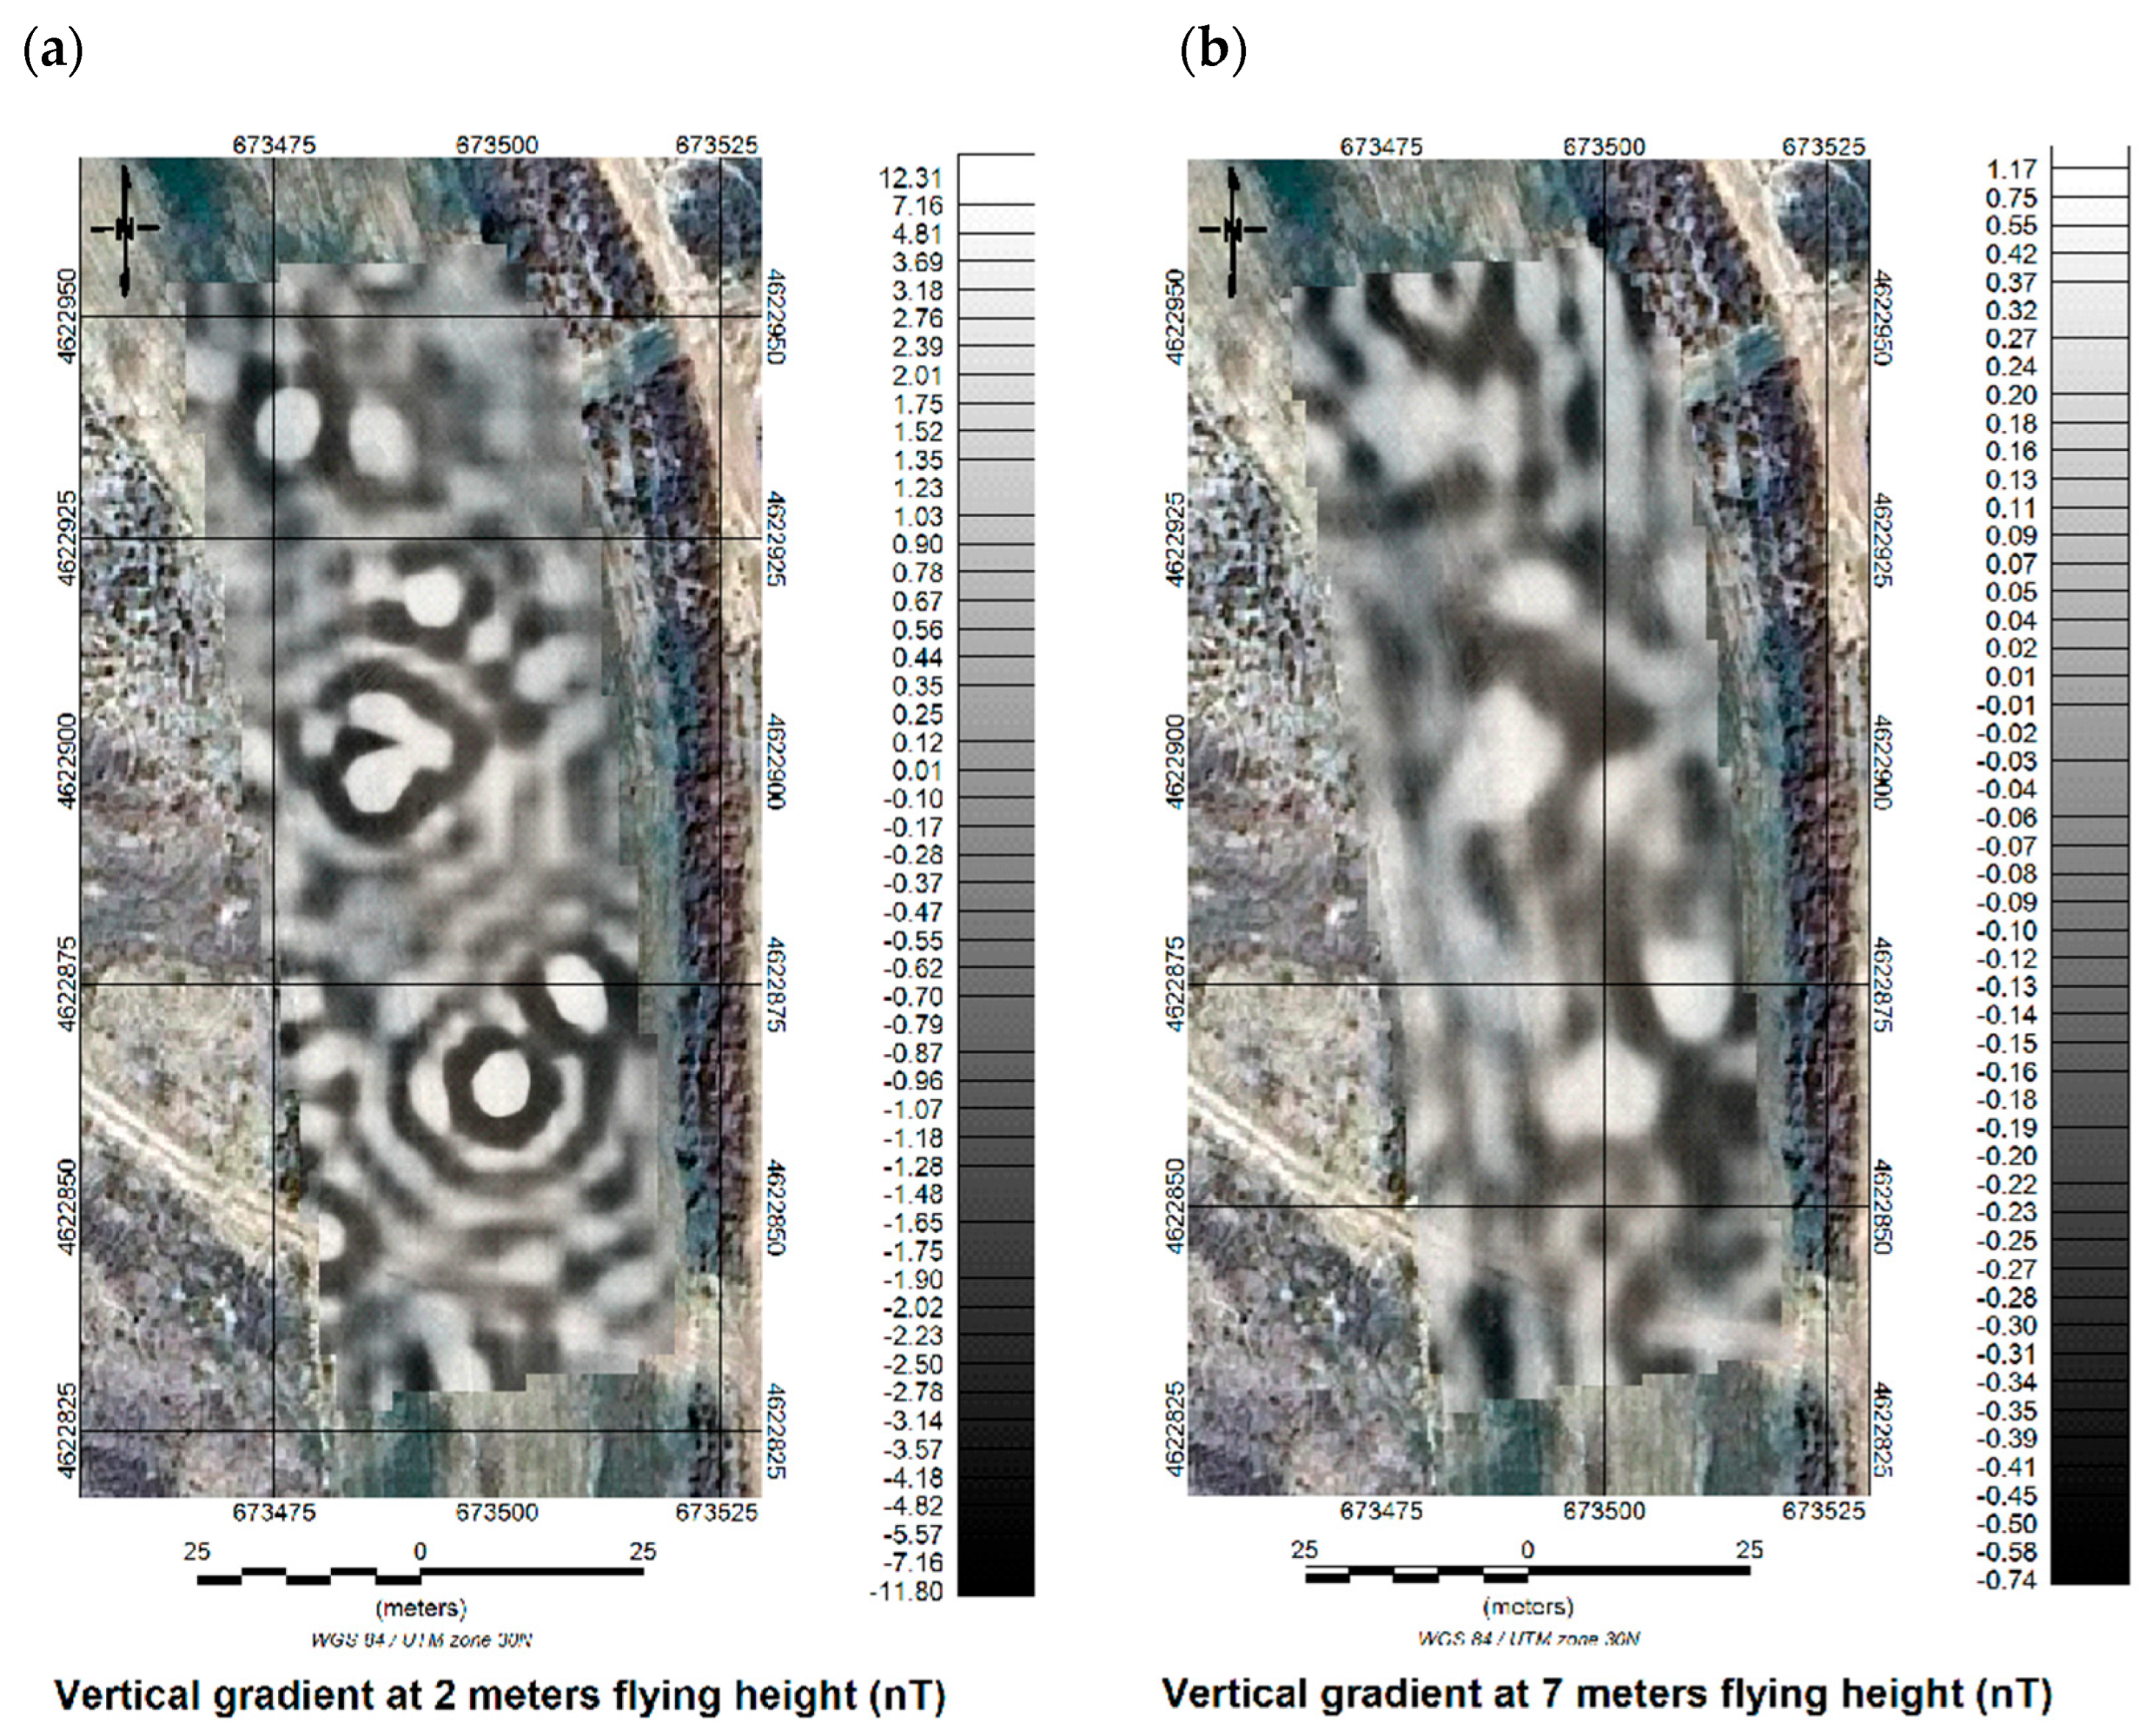
In this study, the VG was calculated from the gridded total magnetic field. The resulting VG maps accentuate abrupt spatial variations in the magnetic field, producing sharper and more localised responses over compact ferromagnetic bodies. Figure 10 illustrates the VG maps obtained for the surveys conducted at 2 m (Figure 10a) and 7 m (Figure 10b) above ground level.
Figure 10.
Vertical Gradient for the 2 m flight (a) and the 7 m flight (b). WGS84/UTM zone 30N (scale in nT).
At the 2 m flight height, the VG maps display well-defined, high-amplitude anomalies directly. These anomalies exhibit compact geometries and steep gradients, consistent with shallow cylindrical ferromagnetic objects. Peak VG values reached approximately ±10–12 nT/m. The circular shape of some anomalies at 2 m height is due to near-field effects at very short sensor–target distances, where compact shallow ferromagnetic sources produce radially symmetric magnetic responses instead of elongated dipoles.
In contrast, the VG maps derived from the 7 m flight height show a clear attenuation of anomaly amplitudes and a loss of sharpness. Although the main anomalies remain identifiable, their VG amplitudes are reduced by approximately 50–60% compared to the 2 m dataset, and their lateral extent becomes broader. This behaviour reflects the strong dependence of VG on sensor–target distance and confirms that VG-based interpretation is most effective when data are acquired at very low heights.
Overall, the VG proved to be a highly effective intermediate transformation, bridging the total magnetic field and the analytic signal. While the VG remains sensitive to noise amplification, particularly at higher flight heights, its application at 2 m above ground level provided a robust enhancement of UXO-related signatures and played a key role in discriminating compact ferromagnetic.
3.6. Analytic Signal (AS)
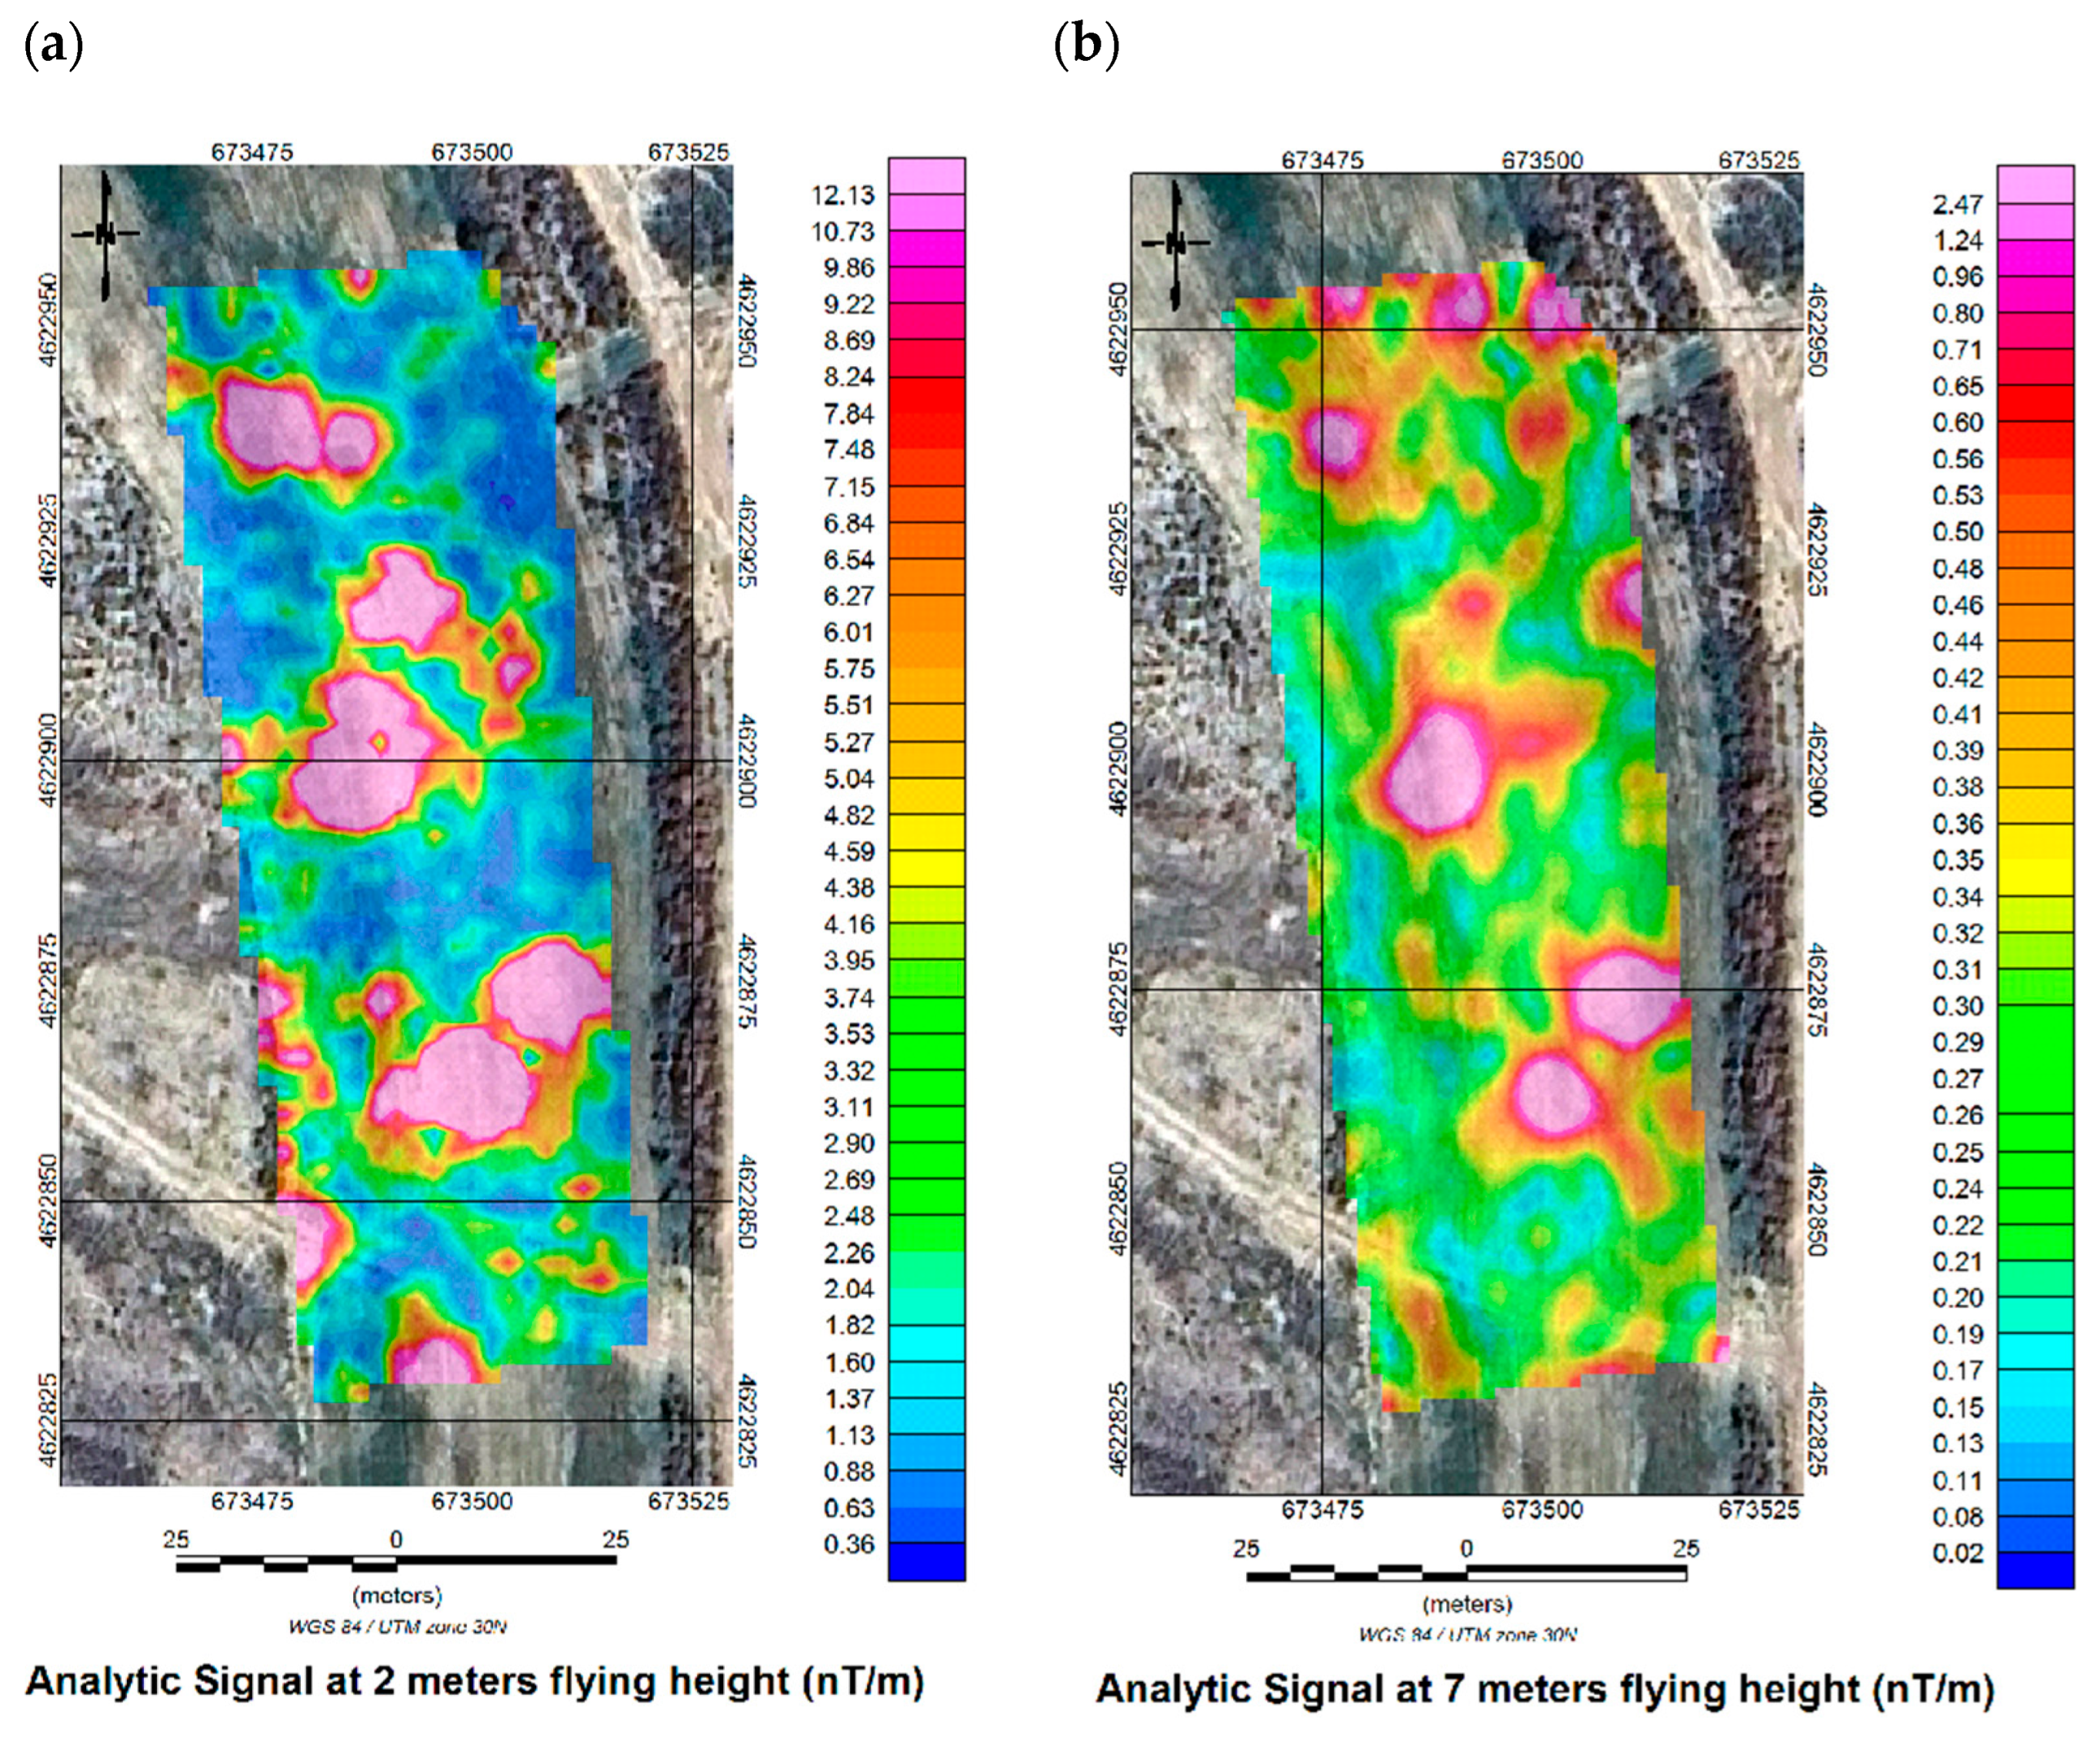
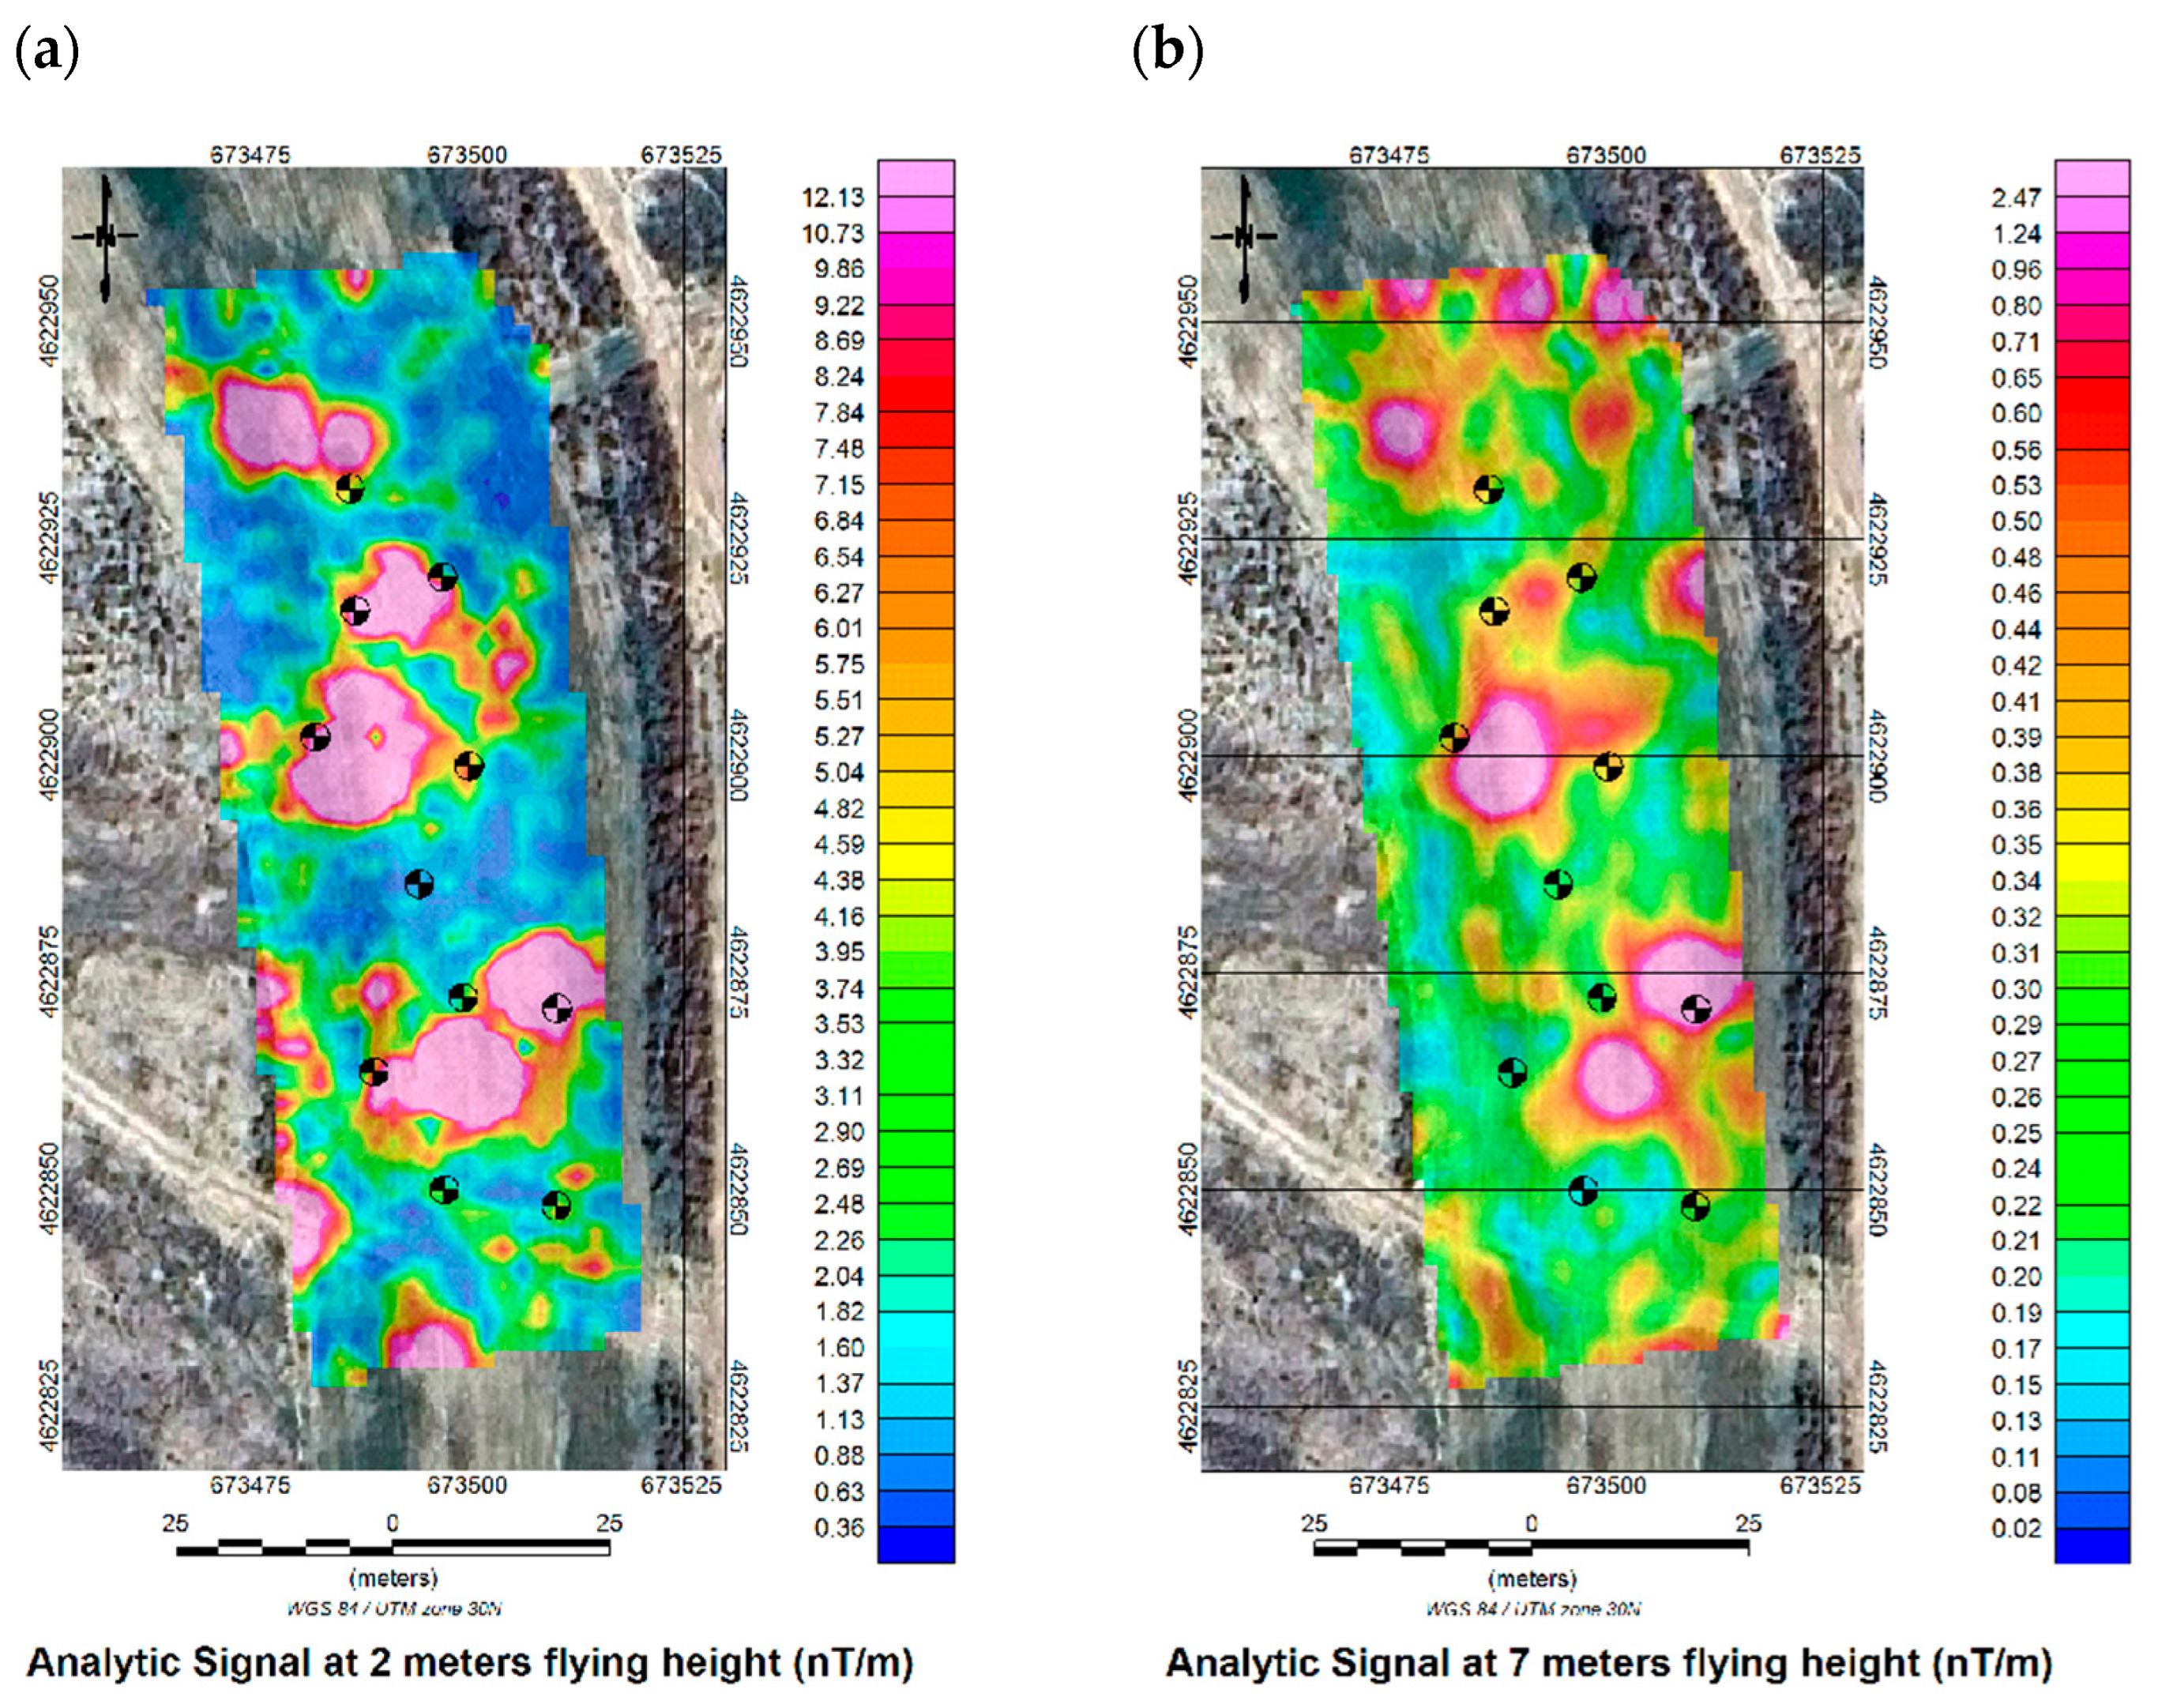
Computation of the analytic signal (AS) enhanced magnetic gradients and sharply delineated the boundaries of magnetic sources. This technique effectively distinguished discrete anomalies compatible with buried UXO from diffuse signals associated with surface shrapnel or spent casings. AS amplitudes exceeded 5 nT/m for UXO, whereas background ferromagnetic debris generally exhibited values < 2 nT/m.
All eleven UXO surrogates produced clear, isolatable analytic-signal peaks, each reflecting its specific size, shape, and burial depth. Larger metallic cylindrical objects (120 and 155 mm) generated broad, high-amplitude responses (up to 15 nT/m), while smaller diameters (60 and 81 mm) showed attenuated but still distinct responses at 2 m height (3–5 nT/m) [38].
Figure 11 presents the AS calculated for the 2 m (a) and 7 m (b) datasets.
Figure 11.
Analytic signal of the magnetic field calculated at 2 m (a) and 7 m (b) height. WGS84/UTM zone 30N (scale in nT/m).
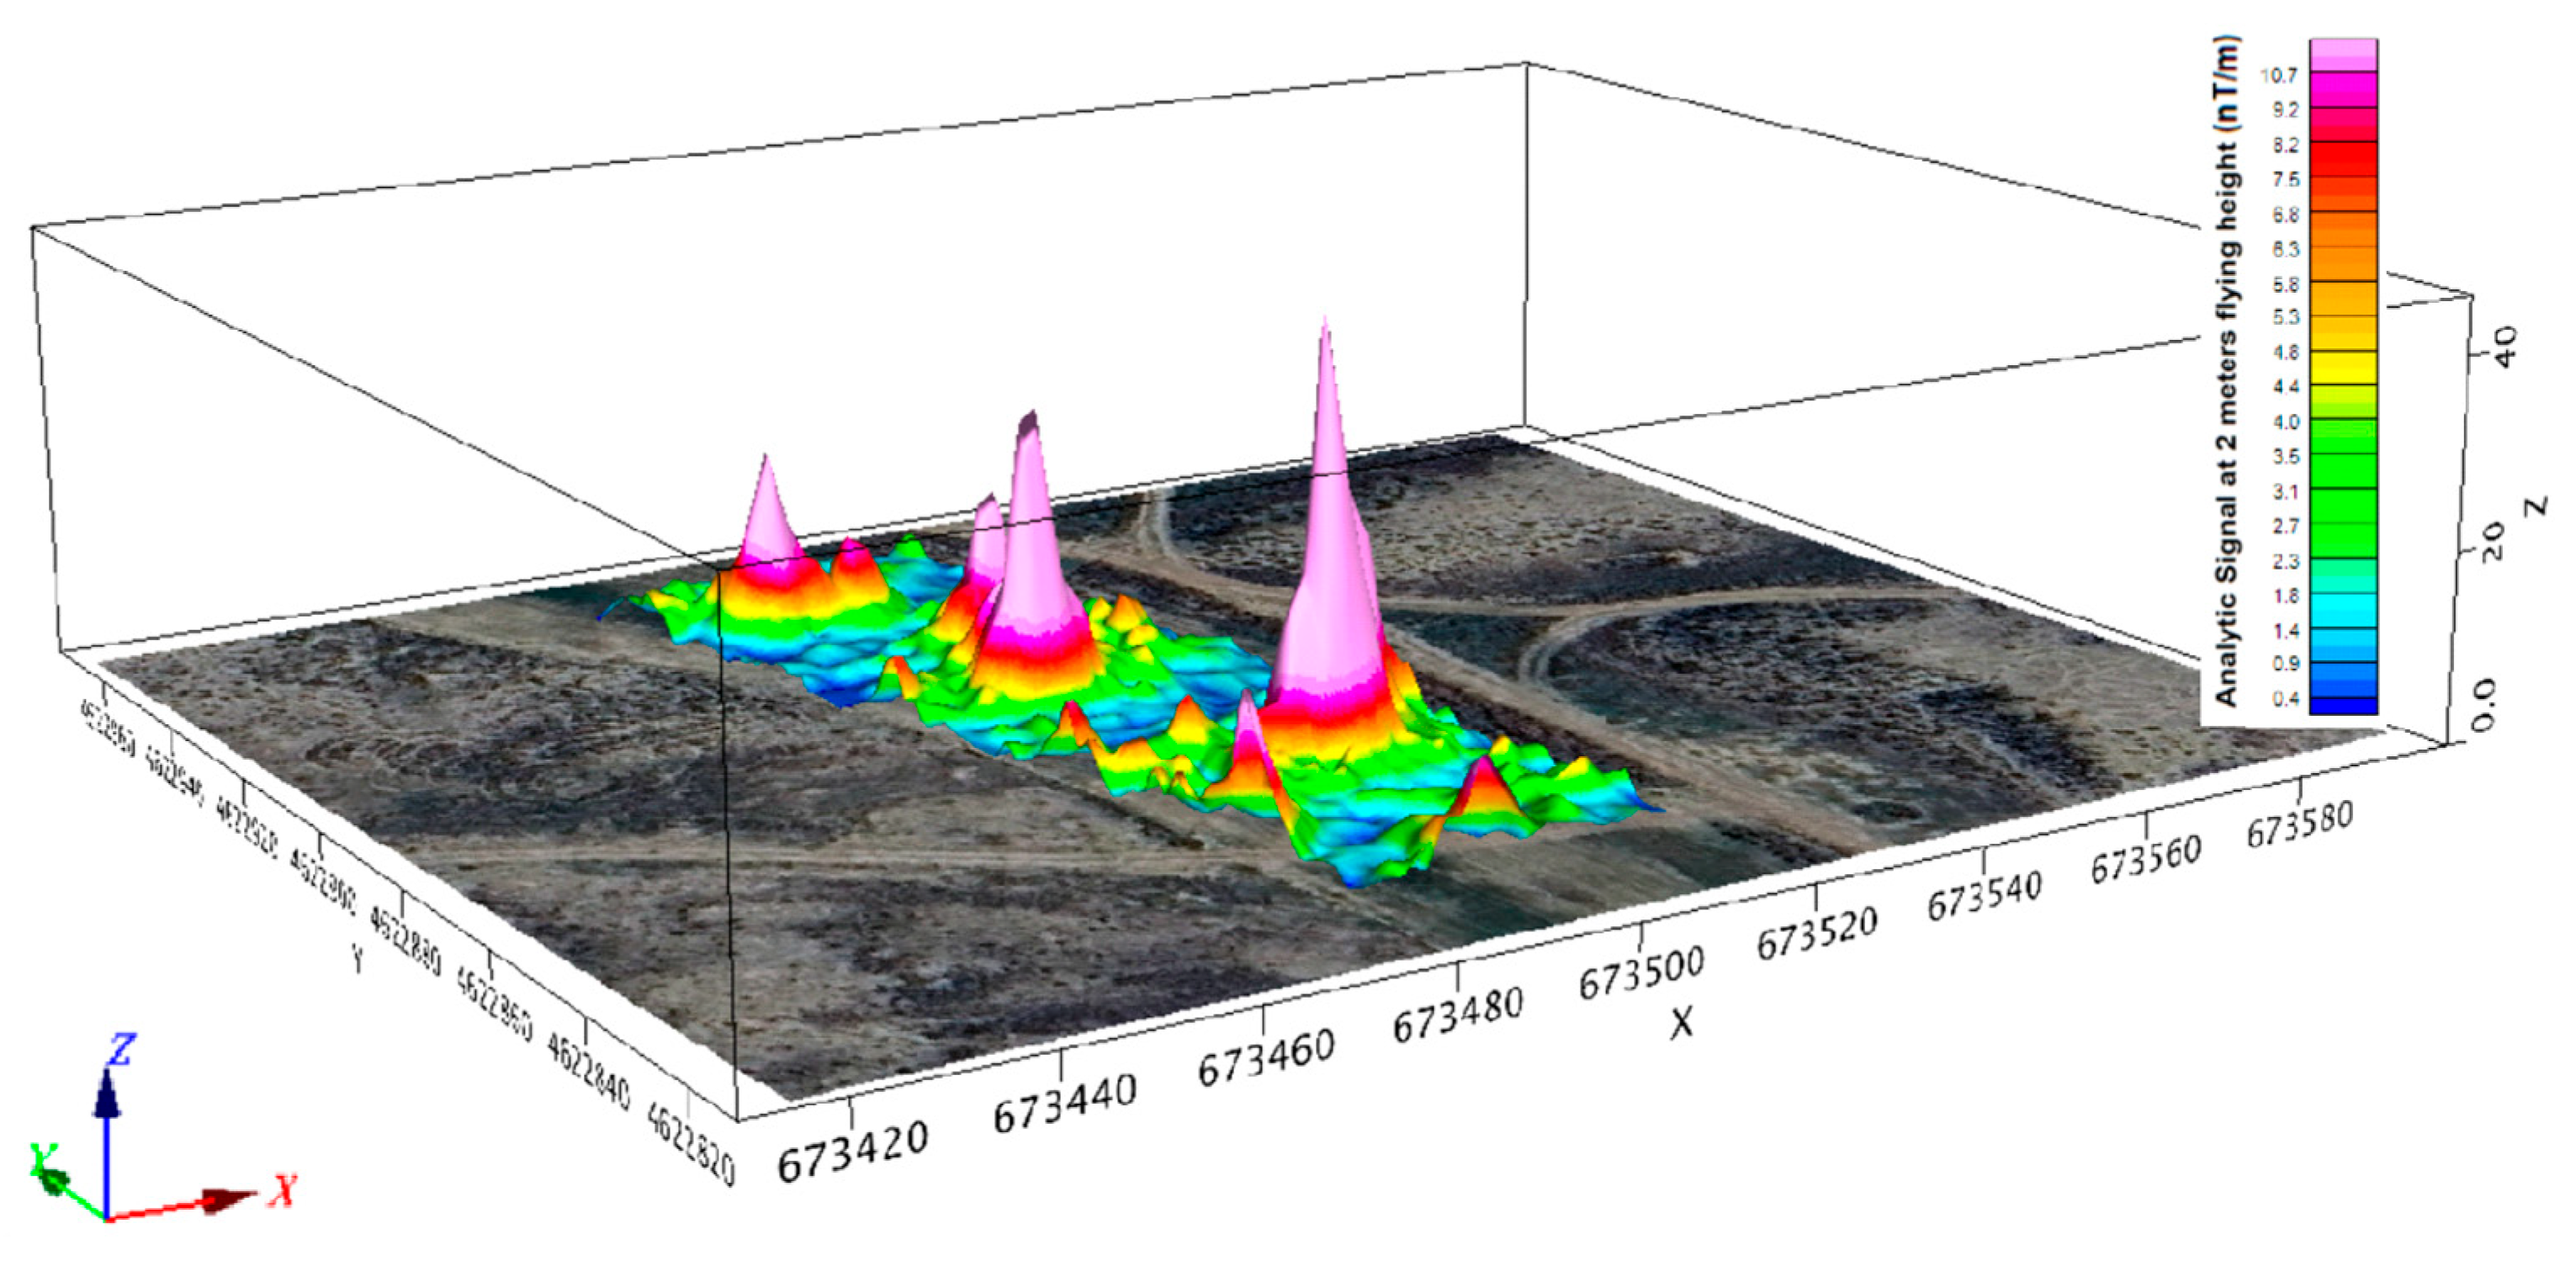
Figure 12 shows a 3D view of the analytic signal for the 2 m flight draped over satellite imagery. This three-dimensional representation provides several important advantages for UXO interpretation:
Figure 12.
Three-dimensional view of the analytic signal (2 m flight) superimposed on satellite imagery. WGS84/UTM zone 30N (scale in nT/m).
- Enhanced spatial context: The overlay on satellite imagery enables direct correlation between magnetic anomalies and surface features (paths, vegetation, terrain changes), facilitating field verification planning.
- Amplitude visualisation: The vertical dimension clearly distinguishes high-amplitude peaks (up to 15 nT/m) associated with larger UXO from lower-amplitude responses (<5 nT/m) likely related to smaller ordnance or surface debris.
- Overlapping anomaly identification: The 3D perspective reveals where multiple anomalies overlap or cluster, which would be difficult to discern in conventional 2D maps. This is particularly important in areas with high ferromagnetic contamination where complex multi-body interactions occur.
- Spatial pattern recognition: The visualisation clarifies the linear distribution of anomalies along the perimeter firebreak, consistent with the expected pattern of UXO landing outside designated impact areas due to ballistic deviations.
This 3D representation thus serves as both an interpretive tool—helping to distinguish genuine UXO targets from noise—and a practical planning resource for guiding ground-based verification teams to priority locations.
Quantitative assessment of false-positive anomalies was conducted by applying a threshold of >6 nT/m to the analytic signal map at 2 m height and identifying all discrete peaks within the surveyed area (Table 4). A total of 27 anomalies exceeded this threshold, of which 11 corresponded to the planted UXO (100% detection), yielding 16 additional anomalies attributable to pre-existing ferromagnetic clutter. This represents a false-positive rate of 59% (16/27 anomalies) at the 6 nT/m threshold.
Table 4.
Threshold-dependent detection performance metrics at 2 m flight height.
When the threshold was increased to >8 nT/m, the number of detected anomalies decreased to 18 (11 UXOs + 7 false positives), improving the signal-to-clutter ratio to 39% false positives while maintaining 100% UXO detection. At >10 nT/m, only 13 anomalies remained (10 UXOs + 3 false positives, with the 60 mm mortar at shallow depth falling below threshold), representing a 23% false-positive rate but 91% UXO detection.
These metrics demonstrate the operational trade-off between detection sensitivity and ground-investigation workload. For the specific conditions of CENAD San Gregorio (extreme ferromagnetic contamination), an operational threshold of 7–8 nT/m appears optimal, balancing high UXO detection rates (100%) with manageable false-positive rates (35–40%). This quantification is essential for planning ground-truthing campaigns and allocating excavation resources efficiently.
3.7. Correlation Between Analytic Signal and UXO Positions
The analytic-signal maps obtained at 2 m (a) and 7 m (b) show a clear correlation with the known positions of the buried UXO surrogates.
At 2 m height, a direct correspondence is evident between local analytic-signal maxima (up to 15 nT/m) and all ferromagnetic UXO, confirming a detection accuracy of approximately 0.5 m. As expected, the non-ferrous control projectile produced no detectable anomaly, reinforcing the selective sensitivity of the method to ferromagnetic materials. At 7 m height, the same anomalies remain visible but show attenuation (~50% reduction) and reduced definition, demonstrating the impact of increased height on anomaly resolution. Numerous additional low-intensity anomalies (2–5 nT/m) of irregular geometry were also detected; these are unrelated to the experimentally buried UXO and likely correspond to residual ferromagnetic debris commonly present in active large-scale outdoor ranges.
In summary, the analytic-signal maps confirm the technique’s ability to detect and precisely locate ferromagnetic UXO, particularly at low height. However, the complex nature of active training ranges—with both controlled and uncontrolled metallic objects—requires careful interpretation and, ideally, prior knowledge of potential background sources.
Figure 13 shows the analytic signal with UXO locations superimposed at 2 m (a) and 7 m (b).
Figure 13.
Analytic signal with superimposed UXO at 2 m (a) and 7 m (b) height. WGS84/UTM zone 30N (scale in nT/m).
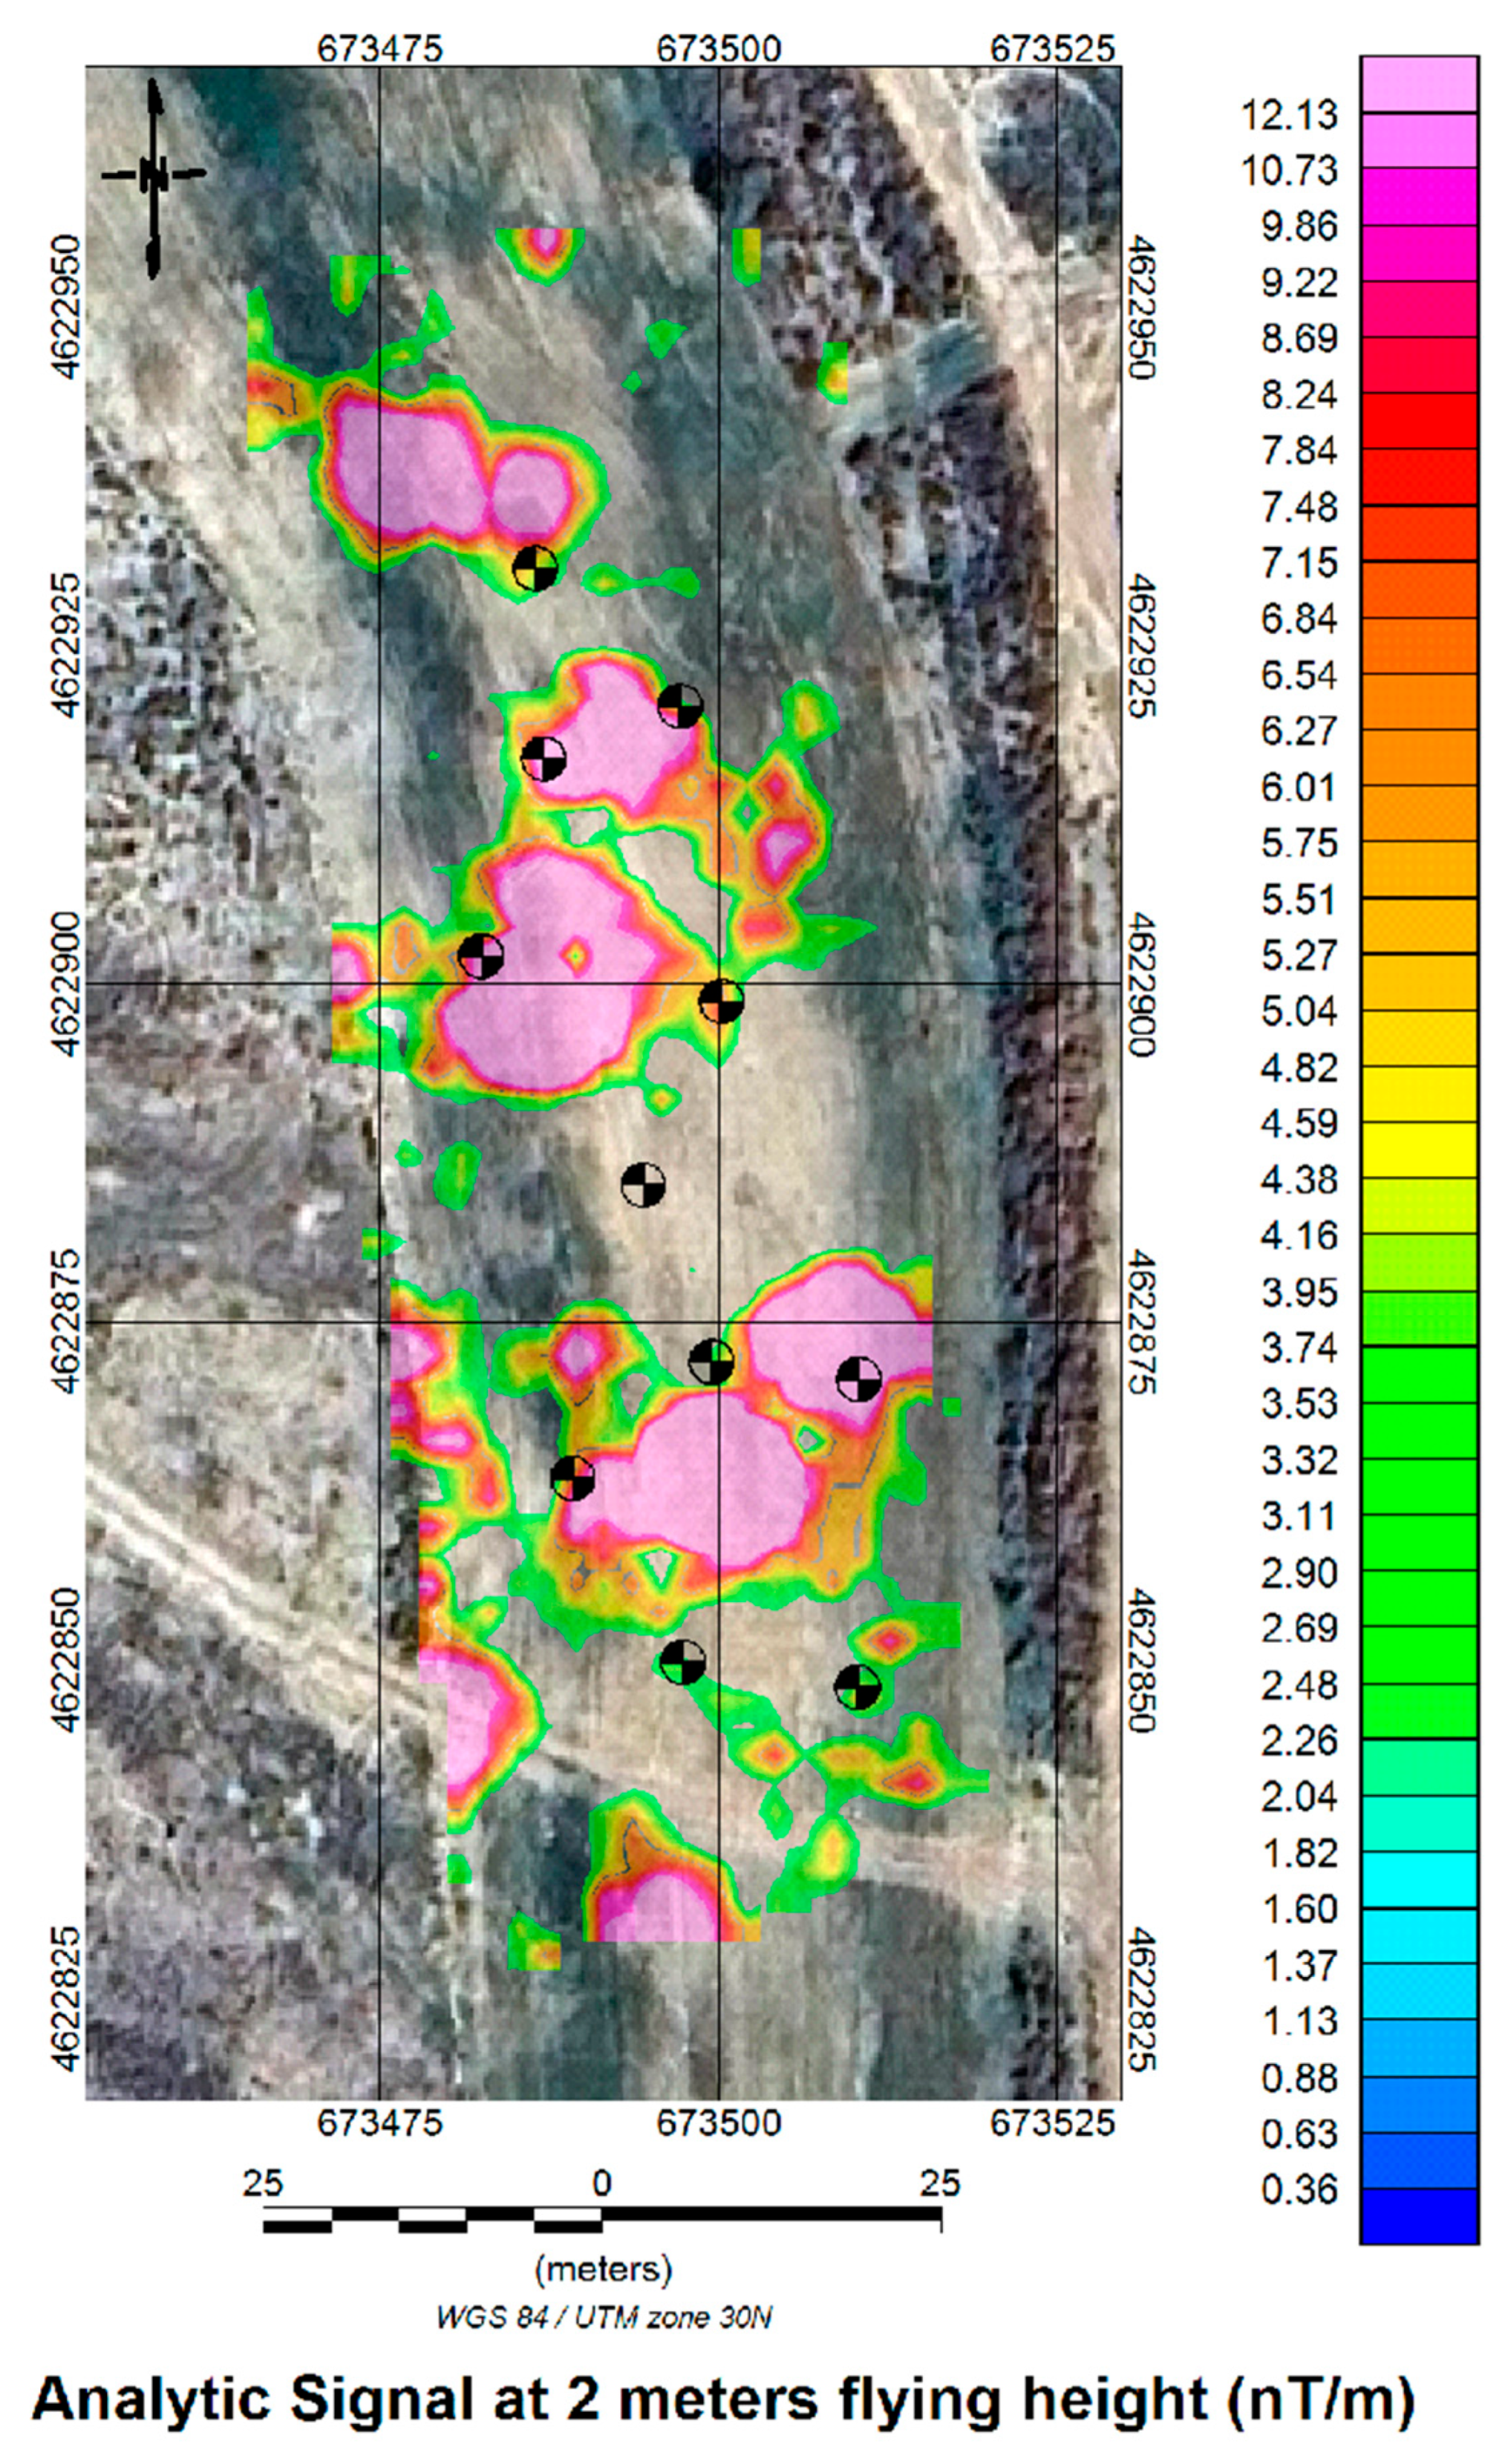
To improve visualisation, thresholded representations of the analytic-signal maxima from the 2 m flight were generated using cut-off values of >6 nT/m and >7 nT/m. These approaches isolate significant anomalies and suppress background noise, allowing for rapid operational interpretation.
Figure 14 displays the thresholded analytic-signal maxima and their relationship to UXO positions.
Figure 14.
Thresholded areas of maximum analytic signal at 2 m height, >2.3 nT, with the location of buried UXOs. WGS84/UTM zone 30N (scale in nT/m).
Figure 14 highlights that most ferromagnetic UXO fall within or immediately adjacent to the analytic-signal maxima, whereas the non-ferrous C/C UXO does not. Additional anomalies not associated with the buried UXO emphasise the complexity of detection in real military environments.
This threshold-based representation is operationally valuable because it enables prioritisation of ground inspection areas by filtering out diffuse magnetic noise and highlighting only high-intensity responses, thereby improving field efficiency.
The analytic-signal response was particularly effective in discriminating UXO-like anomalies from diffuse background clutter. Peak amplitudes of the analytic signal correlated directly with object size and burial depth, confirming the capability of this processing step to detect weak, short-wavelength signatures in noisy settings.
3.8. Three-Dimensional Inversion Modelling
Three-dimensional magnetic susceptibility inversion [22,23] was performed using Oasis Montaj Software to estimate the geometry and depth of the detected sources. In all cases, the estimated depth was <1 m, consistent with the true burial depths.
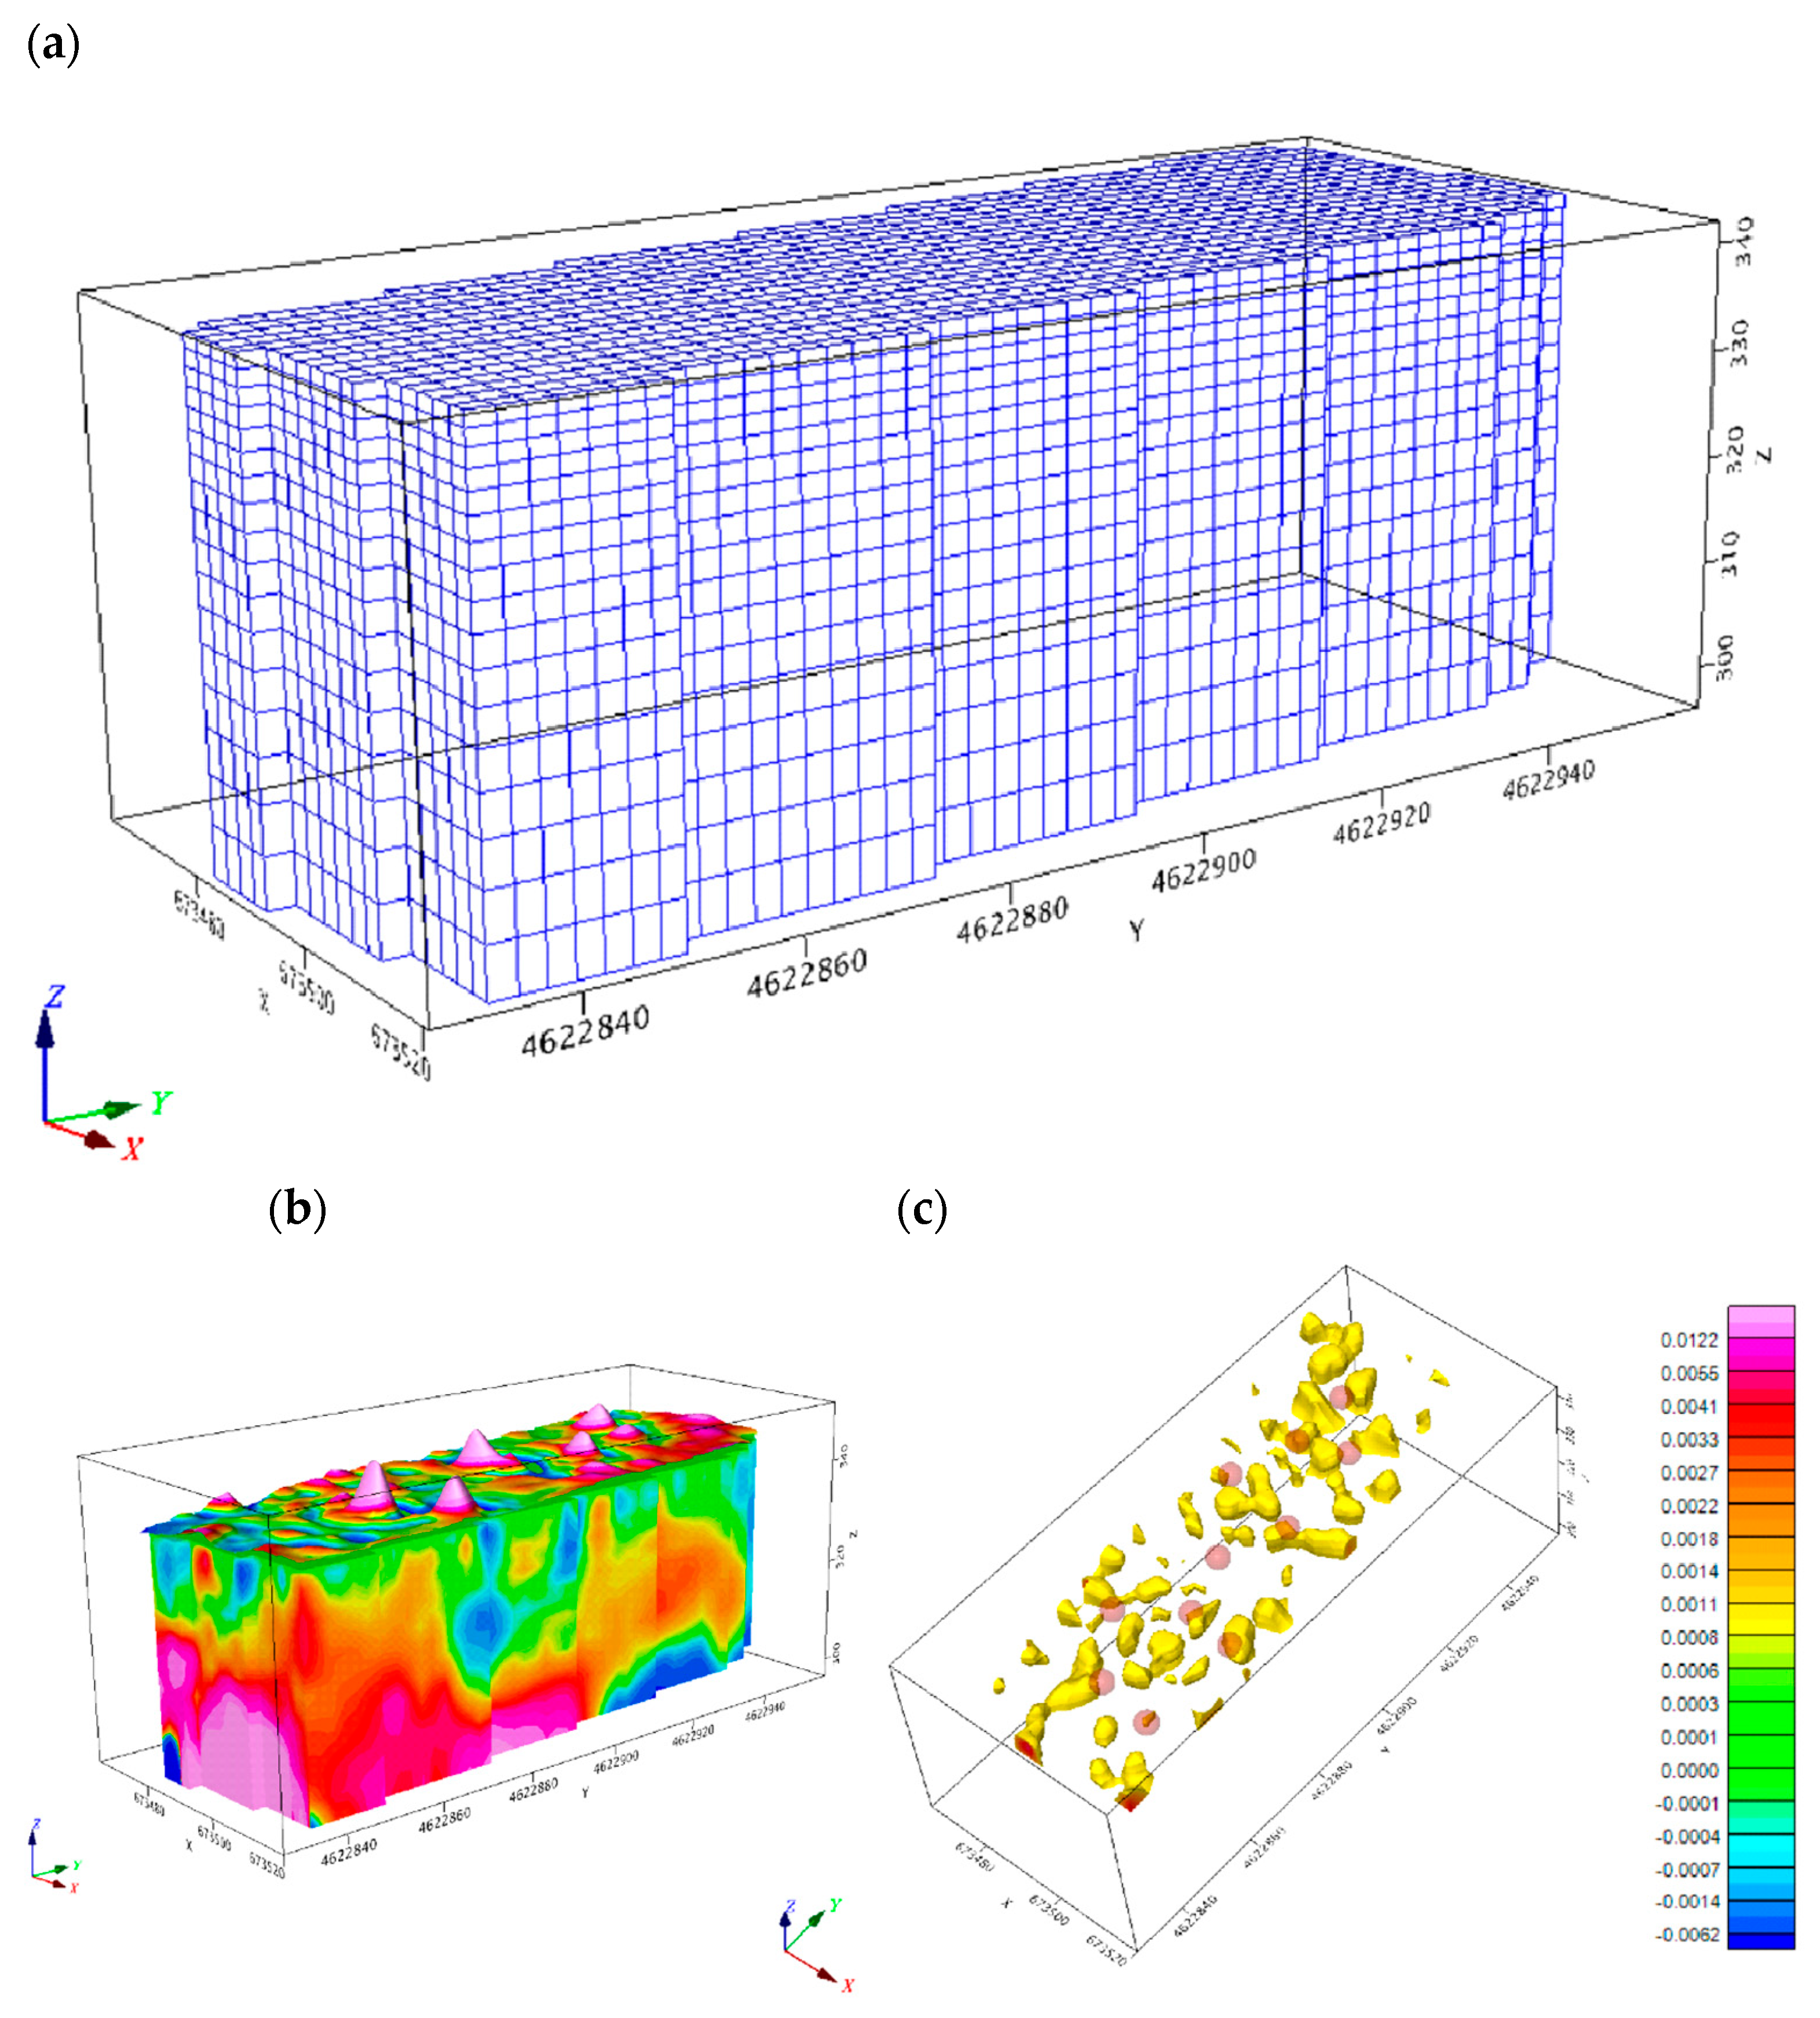
Figure 15a illustrates the discretisation mesh used for the 3D susceptibility inversion model. Figure 15b presents the resulting 3D susceptibility model, showing the distribution of magnetic contrasts in SI units.
Figure 15.
(a) Discretisation mesh used for the 3D magnetic susceptibility inversion model. WGS84/UTM zone 30N (scale in metres). (b) Results of the 3D magnetic susceptibility inversion model showing the three-dimensional (c) Distribution of anomalies (>0.00010 SI) with the location of the unexploded explosive devices buried in the image on the right. WGS84/UTM zone 30N (scale in SI units).
Figure 15b displays the full 3D model, where high-susceptibility regions (>0.0010 SI) appear near the surface and correspond to the UXO and other metallic debris. A complete 3D susceptibility volume extending to 40 m depth was also generated to distinguish near-surface anomalies from deeper geological structures. Figure 15c shows a shallow cut of the model restricted to the upper portion of the inverted volume, where positive-susceptibility isosurfaces highlight the most relevant near-surface sources. This representation suppresses deeper geological background and focuses on discrete, compact bodies indicative of potential UXO, confirming the clustering of ferromagnetic sources near the surface and reinforcing the utility of low-height surveys for detection.
4. Discussion
A key outcome of this work is the demonstration that aerial drone-based magnetometry becomes operationally viable only when supported by a robust processing workflow. The spectral transformations and inversion techniques applied here were fundamental to enhancing anomaly detectability, mitigating the effects of intense ferromagnetic clutter, and improving localisation accuracy.
The results obtained in this study confirm that aerial drone-based aeromagnetic surveying is an effective tool for detecting UXOs under realistic operational conditions. The integrated analysis of total magnetic field maps and derived transformations (reduction to the pole, analytic signal, and 3D inversion) demonstrates that even small metallic objects can be reliably detected when flight heights remain below 3 m and high-sensitivity sensors are combined with dense acquisition grids.
4.1. Influence of Flight Height and Height-Dependent Performance Metrics
The systematic comparison of surveys conducted at 2 m and 7 m above ground level quantified the height-dependent trade-off between detection sensitivity and operational feasibility. At 2 m height, all eleven ferromagnetic UXO surrogates (60–155 mm calibre) were clearly detected with signal-to-noise ratios exceeding 5:1, demonstrating reliable detectability even for the smallest targets (60 mm mortar shells buried at 20–30 cm depth, producing anomalies of 2–5 nT). In contrast, at 7 m height, magnetic anomaly amplitudes decreased by 40–60% due to the cubic attenuation law (B ∝ 1/r3), resulting in marginal detection of smaller-calibre UXO (60 and 81 mm) that approached the 2 nT ambient noise threshold.
These empirical results confirm the theoretical predictions of magnetic dipole behaviour [11] and align with prior controlled studies in the Korean DMZ [6], which established ≤3 m above ground level as the operational threshold for medium-calibre UXO detection. However, the present study extends these findings to a heavily contaminated operational training range with >10 nT RMS background noise—approximately five times higher than previously documented test sites—demonstrating that reliable detection remains achievable at 2 m height when combined with robust filtering of heading errors, platform oscillations, and directional artefacts.
The operational implications are clear: low-height flight protocols (≤3 m) are essential for maximising detection rates, but impose stricter requirements for high-resolution DTMs, real-time terrain-following, obstacle avoidance, and wind-speed limitations (<15 km/h). The achieved 100% detection rate at 2 m height validates the technical feasibility of low-height operations in challenging European training ranges.
While the present study demonstrates optimal UXO detection at ≤3 m above ground level, several operational scenarios—including surveys of extensive training ranges (>10 ha), areas with complex topography, dense vegetation canopies, or high winds—may necessitate higher flight heights. In such contexts, alternative or complementary strategies such as multi-height hierarchical approach, gradiometry systems [4,28,29], high-sensitivity caesium magnetometers [15], multi-sensor fusion or fixed-wing aerial drone platforms could be used.
4.2. Complexity of the Ferromagnetic Environment
San Gregorio Training Center represents a particularly challenging environment due to its high density of scattered metallic debris (shrapnel, casings, and surface scrap), which generates substantial background noise capable of masking weaker anomalies if not properly filtered. Under these conditions, diurnal correction, reduction to the pole and analytic-signal processing proved essential for discriminating between localised anomalies attributable to UXO and diffuse signatures caused by superficial debris.
Despite this complexity, the system successfully located all eleven buried UXO at known positions, demonstrating the robustness of the methodology and its selectivity in distinguishing ferromagnetic objects from non-ferrous materials, as shown by the negative control projectile.
4.3. Efficiency Compared with Ground-Based Methods
Ground-based magnetometry using handheld or towed sensors generally provides high proximity to the target and excellent local resolution, but acquisition times are longer and operators must physically enter potentially hazardous areas. In contrast, aerial drone-based surveys allow rapid coverage of large areas with minimal personnel exposure
In this study, the entire 0.53 ha grid was surveyed in under one hour of effective flight time, achieving a sampling density of one measurement every 25 cm (derived from 1 m line spacing and a 20 Hz sampling rate at 5 m/s). This resolution is comparable to or higher than many terrestrial methods, while maintaining a geolocation accuracy of approximately 0.5 m due to precise DTM integration and post-processing corrections. These results support the growing consensus that aerial drone magnetometry can complement or partially replace ground-based methods in UXO risk assessments.
4.4. Reliability of 3D Modelling
Three-dimensional magnetic susceptibility inversion [20,21] provided accurate estimates of the geometry and depth of buried objects, confirming its value for delineating priority areas. However, model reliability decreases when anomalies are closely spaced or when flight height increases, conditions that reduce vertical and lateral resolution. In such cases, overlapping magnetic responses may complicate conventional inversion.
Future enhancements may include joint inversion algorithms, hybrid approaches integrating GPR or Light Detection and Ranging (LiDAR)-derived terrain models, and machine-learning tools capable of resolving complex multi-body interactions to improve 3D interpretation in cluttered environments.
4.5. Implications for CENAD Management
The successful validation of this methodology provides a promising pathway for optimising reconnaissance and hazard mitigation tasks in controlled outdoor testing/training areas. Integrating routine aerial drone magnetometry into post-exercise inspection procedures could substantially reduce accident risks and improve the management of UXO-contaminated zones by decreasing both the time and cost associated with manual clearance. Moreover, the generation of objective, georeferenced datasets enables the prioritisation of critical areas and supports targeted terrestrial interventions, enhancing personnel safety and operational efficiency. The achieved geolocation accuracy (~0.5 m) is sufficient to direct specialised teams toward precise locations with high confidence, reducing manual search time and improving resource allocation. These findings highlight the potential for aerial drone-based magnetic surveys to become an integral component of UXO risk mitigation strategies in active training facilities, aligning with broader efforts to modernise military environmental management practices. Future research may explore operational integration at larger scales, real-time processing capabilities, and multi-sensor fusion to further improve detection reliability.
5. Conclusions
This study demonstrates that aerial drone-based aeromagnetic surveying constitutes a technically viable and operationally effective solution for UXO detection in active European military training ranges characterised by extreme ferromagnetic contamination. By combining validated performance metrics with a robust, end-to-end data-processing workflow, the work addresses several persistent gaps in the literature and provides one of the most comprehensive operational validations of drone magnetometry under realistic and contaminated field conditions.
Field results obtained at the CENAD San Gregorio training range show that low-height surveys (≈2 m above ground level) can achieve reliable detection of ferromagnetic UXO (60–155 mm calibre) buried at shallow depths (<60 cm), even in environments exhibiting RMS background noise levels exceeding 10 nT. Systematic height comparisons confirm a 40–60% reduction in anomaly amplitude at 7 m, in agreement with magnetic dipole theory, thereby establishing flight heights below approximately 3 m as a practical threshold for small-calibre UXO detection in high-noise settings. When combined with terrain-following flight strategies, diurnal correction, and advanced filtering, the methodology achieved a geolocation accuracy of 0.48 m RMSE, enabling precise targeting and significantly reducing ground-intervention areas.
A key contribution of this work lies in the integrated processing workflow, which proved essential for extracting weak magnetic anomalies from highly contaminated backgrounds. The combination of directional filtering, platform-noise mitigation, spectral transformations, and 3D magnetic susceptibility inversion substantially reduced false positives while maintaining high detection rates, providing practical guidance for balancing sensitivity and operational efficiency. However, due to the specific background of this experiment, UXO detection is affected by some false positives. These may be related to small magnetic sources inherent to the local geological context.
From an operational perspective, the aerial drone-based approach enabled rapid area coverage—approximately an order of magnitude faster than traditional ground surveys—while minimising personnel exposure to hazardous terrain.
Overall, this study represents the first fully ground-truthed application of aerial drone magnetometry in an actively used European training range, delivering region-specific performance benchmarks under mid-latitude geomagnetic conditions and within European regulatory frameworks. The results confirm the role of aerial drone magnetometry not as a replacement for ground-based methods, but as a powerful pre-classification and prioritisation tool that can substantially improve the safety, efficiency, and cost-effectiveness of UXO clearance operations.
Future work should focus on real-time processing capabilities, multi-sensor data fusion, automated classification strategies, and broader validation across diverse operational settings, with the aim of developing standardised and transferable protocols for routine military and humanitarian applications.
Author Contributions
The first author I.U.-G. is currently conducting his doctoral research on the application of geotechnologies in controlled outdoor testing/training areas and led the overall development of the study. Conceptualization, I.U.-G. and D.G.-A.; methodology, I.U.-G.; software, I.U.-G., P.C.-G. and J.C.-G.; validation, I.U.-G., D.G.-A., D.G.-S. and P.C.-G.; formal analysis, I.U.-G.; investigation, I.U.-G.; resources, D.G.-A.; data curation, I.U.-G.; writing—original draft preparation, I.U.-G.; writing—review and editing, D.G.-A.; visualisation, I.U.-G.; supervision, D.G.-A.; project administration, D.G.-A.; funding acquisition, D.G.-A. The corresponding author D.G.-A. is the doctoral supervisor and head of the TIDOP research group, contributing expertise in geotechnologies and overseeing the scientific development of the work. The third and fourth authors P.C.-G. and J.C.-G. are specialist in magnetometry, including airborne systems, and contributed technical expertise to the design, interpretation, and validation of the magnetic measurements. The second author D.G.-S. is an expert in aerial drone systems and contributed specialised knowledge on drone integration, flight planning, and operational management. All authors have read and agreed to the published version of the manuscript.
Funding
This research received no external funding.
Data Availability Statement
The data supporting the findings of this study are available from the corresponding author upon reasonable request. Due to the sensitive nature of the controlled outdoor testing/training area where the experiment was conducted, the complete raw dataset with precise coordinates cannot be publicly released for security reasons. However, processed data products (including gridded magnetic field maps, analytic signal grids, and 3D susceptibility models) with coordinates anonymised or referenced to a local coordinate system can be made available to researchers for verification and reproducibility purposes. Flight metadata, processing parameters, and technical specifications are fully documented in the manuscript.
DURC Statement
The present research is restricted to the defence and civilian application of aerial drone magnetometry for the detection of unexploded ordnance (UXO). One of the principal beneficial outcomes of this study is its contribution to humanitarian demining, as the proposed methodology enables the remote detection of buried landmines and UXO without exposing human personnel to danger. By allowing survey operations to be carried out from the air, this approach significantly reduces the risk to demining teams and supports safer, more efficient clearance activities in contaminated areas. The study does not involve the development, testing, or enhancement of weapon systems, nor does it pose any foreseeable risk to public health, safety, or national security. The authors acknowledge the potential dual-use nature of geophysical sensing technologies and confirm that all activities were conducted in full compliance with applicable national and international regulations governing dual-use research. In line with ethical responsibilities, the authors have implemented appropriate safeguards, adhered to responsible research practices, and ensured transparent reporting to minimise any risk of misuse. The research is therefore directed solely towards beneficial, peaceful, and humanitarian applications, contributing to safer environments in post-conflict regions.
Acknowledgments
The authors thank the personnel of the San Gregorio Training Center (CENAD) for their logistical support during the field campaign. The authors also acknowledge the technical assistance provided by the TIDOP Research Group (University of Salamanca) in the aerial drone integration and geophysical data processing. The authors would like to acknowledge Seequent for their support and the use of Oasis Montaj software, which was essential for the development of this work.
Conflicts of Interest
The authors declare no conflicts of interest. The funders had no role in the design of the study; in the collection, analyses, or interpretation of data; in the writing of the manuscript; or in the decision to publish the results.
References
- Butler, D.K. Implications of magnetic backgrounds for unexploded ordnance detection. Appl. Geophys. 2003, 54, 111–125. [Google Scholar] [CrossRef] [Scilit]
- Billings, S.D.; Youmans, C. Field measurement of induced and remanent moments of unexploded ordnance and shrapnel. IEEE Trans. Geosci. Remote Sens. 2009, 47, 815–827. [Google Scholar] [CrossRef]
- Butler, D.K.; Wolfe, P.; Hansen, R. Analytical Modeling of Magnetic and Gravity Signatures of Unexploded Ordnance. Environ. Eng. Geophys. 2001, 6, 33–46. [Google Scholar] [CrossRef] [Scilit]
- Samadzadegan, F.; Qaderi, F.; Haghighi, T.L.; Toosi, A.; Mousavi, S.M. Unmanned Aerial Remote Sensing for Unexploded Ordnance Detection: Concepts, Methods, Current Status and Trends. Sens. Imaging 2025, 26, 137. [Google Scholar] [CrossRef] [Scilit]
- Mu, Y.; Xie, W.; Zhang, X. The Joint UAV-Borne Magnetic Detection System and Cart-Mounted Time Domain Electromagnetic System for UXO Detection. Remote Sens. 2021, 13, 2343. [Google Scholar] [CrossRef] [Scilit]
- Yoo, L.-S.; Lee, J.-H.; Lee, Y.-K.; Jung, S.-K.; Choi, Y. Application of a Drone Magnetometer System to Military Mine Detection in the Demilitarized Zone. Sensors 2021, 21, 3175. [Google Scholar] [CrossRef] [Scilit]
- Pasion, L.; Oldenburg, D.W. Locating UXO Using the Magnetic Gradient Tensor. Geophysics 2001, 66, 571–582. [Google Scholar] [CrossRef] [Scilit]
- Zheng, X.; Tian, Y.; Wang, B. A Magnetic Gradient Tensor Based Method for UXO Detection on Movable Platform. IEEE Trans. Geosci. Remote Sens. 2023, 61, 1–9. [Google Scholar] [CrossRef] [Scilit]
- Byrnes, J. Unexploded Ordnance Detection and Mitigation; Springer: Dordrecht, The Netherlands, 2008. [Google Scholar]
- Zhdanov, M.S. Inverse Theory and Applications in Geophysics, 2nd ed.; Elsevier: Amsterdam, The Netherlands, 2015; ISBN 978-0444626745. [Google Scholar]
- Nabighian, M.N.; Ander, M.E.; Grauch, V.J.S.; Hansen, R.O.; LaFehr, T.R.; Li, Y.; Pearson, W.C.; Peirce, J.W.; Phillips, J.D.; Ruder, M.E. The Historical Development of the Magnetic Method in Exploration. Geophysics 2005, 70, 33ND–61ND. [Google Scholar] [CrossRef] [Scilit]
- Pašteka, R.; Hajach, M.; Brixová, B.; Mikuška, J.; Stanley, J. Real magnetic stripping method in unexploded ordnance detection and remediation—A case study from Rohožník military training range in SW Slovakia. Contrib. Geophys. Geod. 2021, 51, 277–294. [Google Scholar] [CrossRef] [Scilit]
- Li, Y.; Han, Q.; Peng, X.; Li, Q.; Tong, X. A Magnetic Interference Compensation Method for Airborne Electronic Equipment without Current Sensors. Remote Sens. 2022, 14, 4151. [Google Scholar] [CrossRef] [Scilit]
- Walter, C.A.; Braun, A.; Fotopoulos, G. Impact of Three-Dimensional Attitude Variations of an Unmanned Aerial Vehicle Magnetometry System on Magnetic Data Quality. Geophys. Prospect. 2019, 67, 465–479. [Google Scholar] [CrossRef] [Scilit]
- Brants, M.; Kucenko, S. UAV-Based Magnetometer Comparison: UXO Test. SPH Engineering SUAS News. 2023. Available online: https://www.sphengineering.com/news/uav-based-magnetometer-comparison-uxo-test (accessed on 20 January 2026).
- Gamey, T.J.; Doll, W.E.; Beard, L.P. Initial design and testing of a full-tensor airborne SQUID magnetometer for detection of unexploded ordnance. In Proceedings of the SEG Technical Program Expanded Abstracts 2004; ASME: New York, NY, USA, 2004; pp. 798–801. [Google Scholar] [CrossRef] [Scilit]
- Jirigalatu, J.; Døssing, A.; Lima Simões da Silva, E. Noise Analysis of a Portable Aeromagnetic Surveying System Using a Hybrid UAV. In NSG2020 3rd Conference on Geophysics for Mineral Exploration and Mining; European Association of Geoscientists & Engineers: Houten, The Netherlands, 2020; Volume 2020, pp. 1–5. [Google Scholar] [CrossRef] [Scilit]
- Poliachenko, I.; Kozak, V.; Bakhmutov, V.; Cherkes, S.; Bilyi, T. Exploratory study of potential applications of UAV magnetic surveys for unexploded ordnance detection in coastline zone. Geofiz. Zhurnal 2025, 47, 97–107. [Google Scholar] [CrossRef] [Scilit]
- Poliachenko, I.; Kozak, V.; Bakhmutov, V.; Cherkes, S.; Varava, I. Preliminary results of UAV magnetic surveys for unexploded ordnance detection in Ukraine: Effectiveness and challenges. Geofiz. Zhurnal 2023, 45, 126140. [Google Scholar] [CrossRef] [Scilit]
- Seidel, M.; Frey, T.; Greinert, J. Underwater UXO Detection Using Magnetometry on Hovering AUVs. J. Field Robot. 2023, 40, 848–861. [Google Scholar] [CrossRef] [Scilit]
- Li, Y.; Oldenburg, D.W. 3-D Inversion of Magnetic Data. Geophysics 1996, 61, 394–408. [Google Scholar] [CrossRef] [Scilit]
- Portniaguine, O.; Zhdanov, M.S. 3-D magnetic inversion with data compression and image focusing. Geophysics 2002, 67, 1532–1541. [Google Scholar] [CrossRef] [Scilit]
- Beiki, M.; Pedersen, L.B. Eigenvector analysis of gravity gradient tensor to locate geologic bodies. Geophysics 2010, 75, I37–I49. [Google Scholar] [CrossRef] [Scilit]
- Kolster, M.E.; Døssing, A. Scalar magnetic difference inversion applied to UAV-based UXO detection. Geophys. J. International. 2021, 224, 468–486. [Google Scholar] [CrossRef] [Scilit]
- Kolster, M.E.; Wigh, M.D.; Lima Simões da Silva, E.; Bjerg Vilhelmsen, T.; Døssing, A. High-Speed Magnetic Surveying for Unexploded Ordnance Using UAV Systems. Remote Sens. 2022, 14, 1134. [Google Scholar] [CrossRef] [Scilit]
- Fedi, M.; Quarta, T. Wavelet Analysis for the Regional-Residual and Local Separation of Potential Field Anomalies. Geophys. Prospect. 1998, 46, 507–525. [Google Scholar] [CrossRef] [Scilit]
- Fedi, M.; Florio, G. Detection of Potential Fields Source Boundaries by Enhanced Horizontal Derivative Method. Geophys. Prospect. 2001, 49, 40–58. [Google Scholar] [CrossRef] [Scilit]
- Accomando, F.; Barone, A.; Mercogliano, F.; Milano, M.; Vitale, A.; Castaldo, R.; Tizzani, P. Advances in Magnetic UAV Sensing: A Comparative Study of the MagNimbus and MagArrow Magnetometers. Sensors 2025, 25, 6076. [Google Scholar] [CrossRef] [Scilit]
- Accomando, F.; Florio, G. Drone-Borne Magnetic Gradiometry in Archaeological Applications. Sensors 2024, 24, 4270. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Shubitidze, F.; Fernández, J.P.; Barrowes, B.E.; Shamatava, I.; Bijamov, A.; O’Neill, K.; Karkashadze, D. The Orthonormalized Volume Magnetic Source Model for Discrimination of Unexploded Ordnance. IEEE Trans. Geosci. Remote Sens. 2014, 52, 4658–4670. [Google Scholar] [CrossRef] [Scilit]
- Pilkington, M. 3-D Magnetic Data-Space Inversion with Sparseness Constraints. Geophysics 2009, 74, L7–L15. [Google Scholar] [CrossRef] [Scilit]
- Li, X. Understanding 3D analytic signal amplitude. Geophysics 2006, 71, 13–16. [Google Scholar] [CrossRef] [Scilit]
- Hoffmann, A.P.; Finley, M.G.; Zesta, E.; Moldwin, M.B.; Ojeda, L.V. A Drone-mounted Magnetometer System for Automatic Interference Removal and Landmine Detection. arXiv 2025, arXiv:2510.01417v1. Available online: https://arxiv.org/abs/2510.01417v1 (accessed on 20 January 2026). [CrossRef] [Scilit]
- Oldenburg, D.W.; Li, Y. Estimating Depth of Investigation in DC Resistivity and IP Surveys. Geophysics 1999, 64, 403–416. [Google Scholar] [CrossRef] [Scilit]
- Malehmir, A.; Dynesius, L.; Paulusson, K.; Paulusson, A.; Johansson, H.; Bastani, M.; Wedmark, M.; Marsden, P. The Potential of Rotary-Wing UAV-Based Magnetic Surveys for Mineral Exploration: A Case Study from Central Sweden. Lead. Edge 2017, 36, 552–557. [Google Scholar] [CrossRef] [Scilit]
- Hansen, R.O.; Pawlowski, R.S. Reduction to the pole at low latitudes by Wiener filtering. Geophysics 1989, 54, 1607–1613. [Google Scholar] [CrossRef] [Scilit]
- Roest, W.R.; Verhoef, J.; Pilkington, M. Magnetic Interpretation Using the 3-D Analytic Signal. Geophysics 1992, 57, 116–125. [Google Scholar] [CrossRef] [Scilit]
- Zhdanov, M.S.; Lee, S.K.; Yoshioka, K. Integral equation method for 3D modeling of electromagnetic fields in complex structures with inhomogeneous background conductivity. Geophysics 2006, 71, G333–G345. [Google Scholar] [CrossRef] [Scilit]

Disclaimer/Publisher’s Note: The statements, opinions and data contained in all publications are solely those of the individual author(s) and contributor(s) and not of MDPI and/or the editor(s). MDPI and/or the editor(s) disclaim responsibility for any injury to people or property resulting from any ideas, methods, instructions or products referred to in the content. |
© 2026 by the authors. Licensee MDPI, Basel, Switzerland. This article is an open access article distributed under the terms and conditions of the Creative Commons Attribution (CC BY) license.