Designing C2 Links for BVLOS UAS Operations



Highlights
- Defining and achieving bandwidth and latency performance metrics that cater for Beyond Visual Line-of-Sight (BVLOS) drone operations is a complex study that requires the design and analysis of telecommunication networks, avionics hardware, and embedded software.
- MBSE (Model-Based Systems Engineering) effectively consolidates complex requirements from EU regulators, telecom providers, and drone operators, facilitating focused design and regulatory alignment.
- Key attributable metrics for BVLOS operations can be targeted to specific stakeholders and provide realistic goals for long-term sustainable planning as BVLOS operations transit from rural to urban areas in Europe.
- The MBSE method is shown to provide a baseline design that is iterative and translatable to similar operational scenarios, and which will enhance speed of regulatory approval while taking into account the new and evolving safety and technical requirements being made by EU regulatory bodies.
Abstract
1. Introduction
- Develop an MBSE guide for designing C2 data links in BVLOS operations.
- Link architecture diagram connectors to system functions, enabling their use in regulatory verification.
- Align software verification tests with requirements tied to validated MBSE objectives.
2. Preliminaries
2.1. Specific Operations Risk Assessment (SORA)
2.2. Drone Communication Networks
3. MBSE for Safe BVLOS Flight Operations
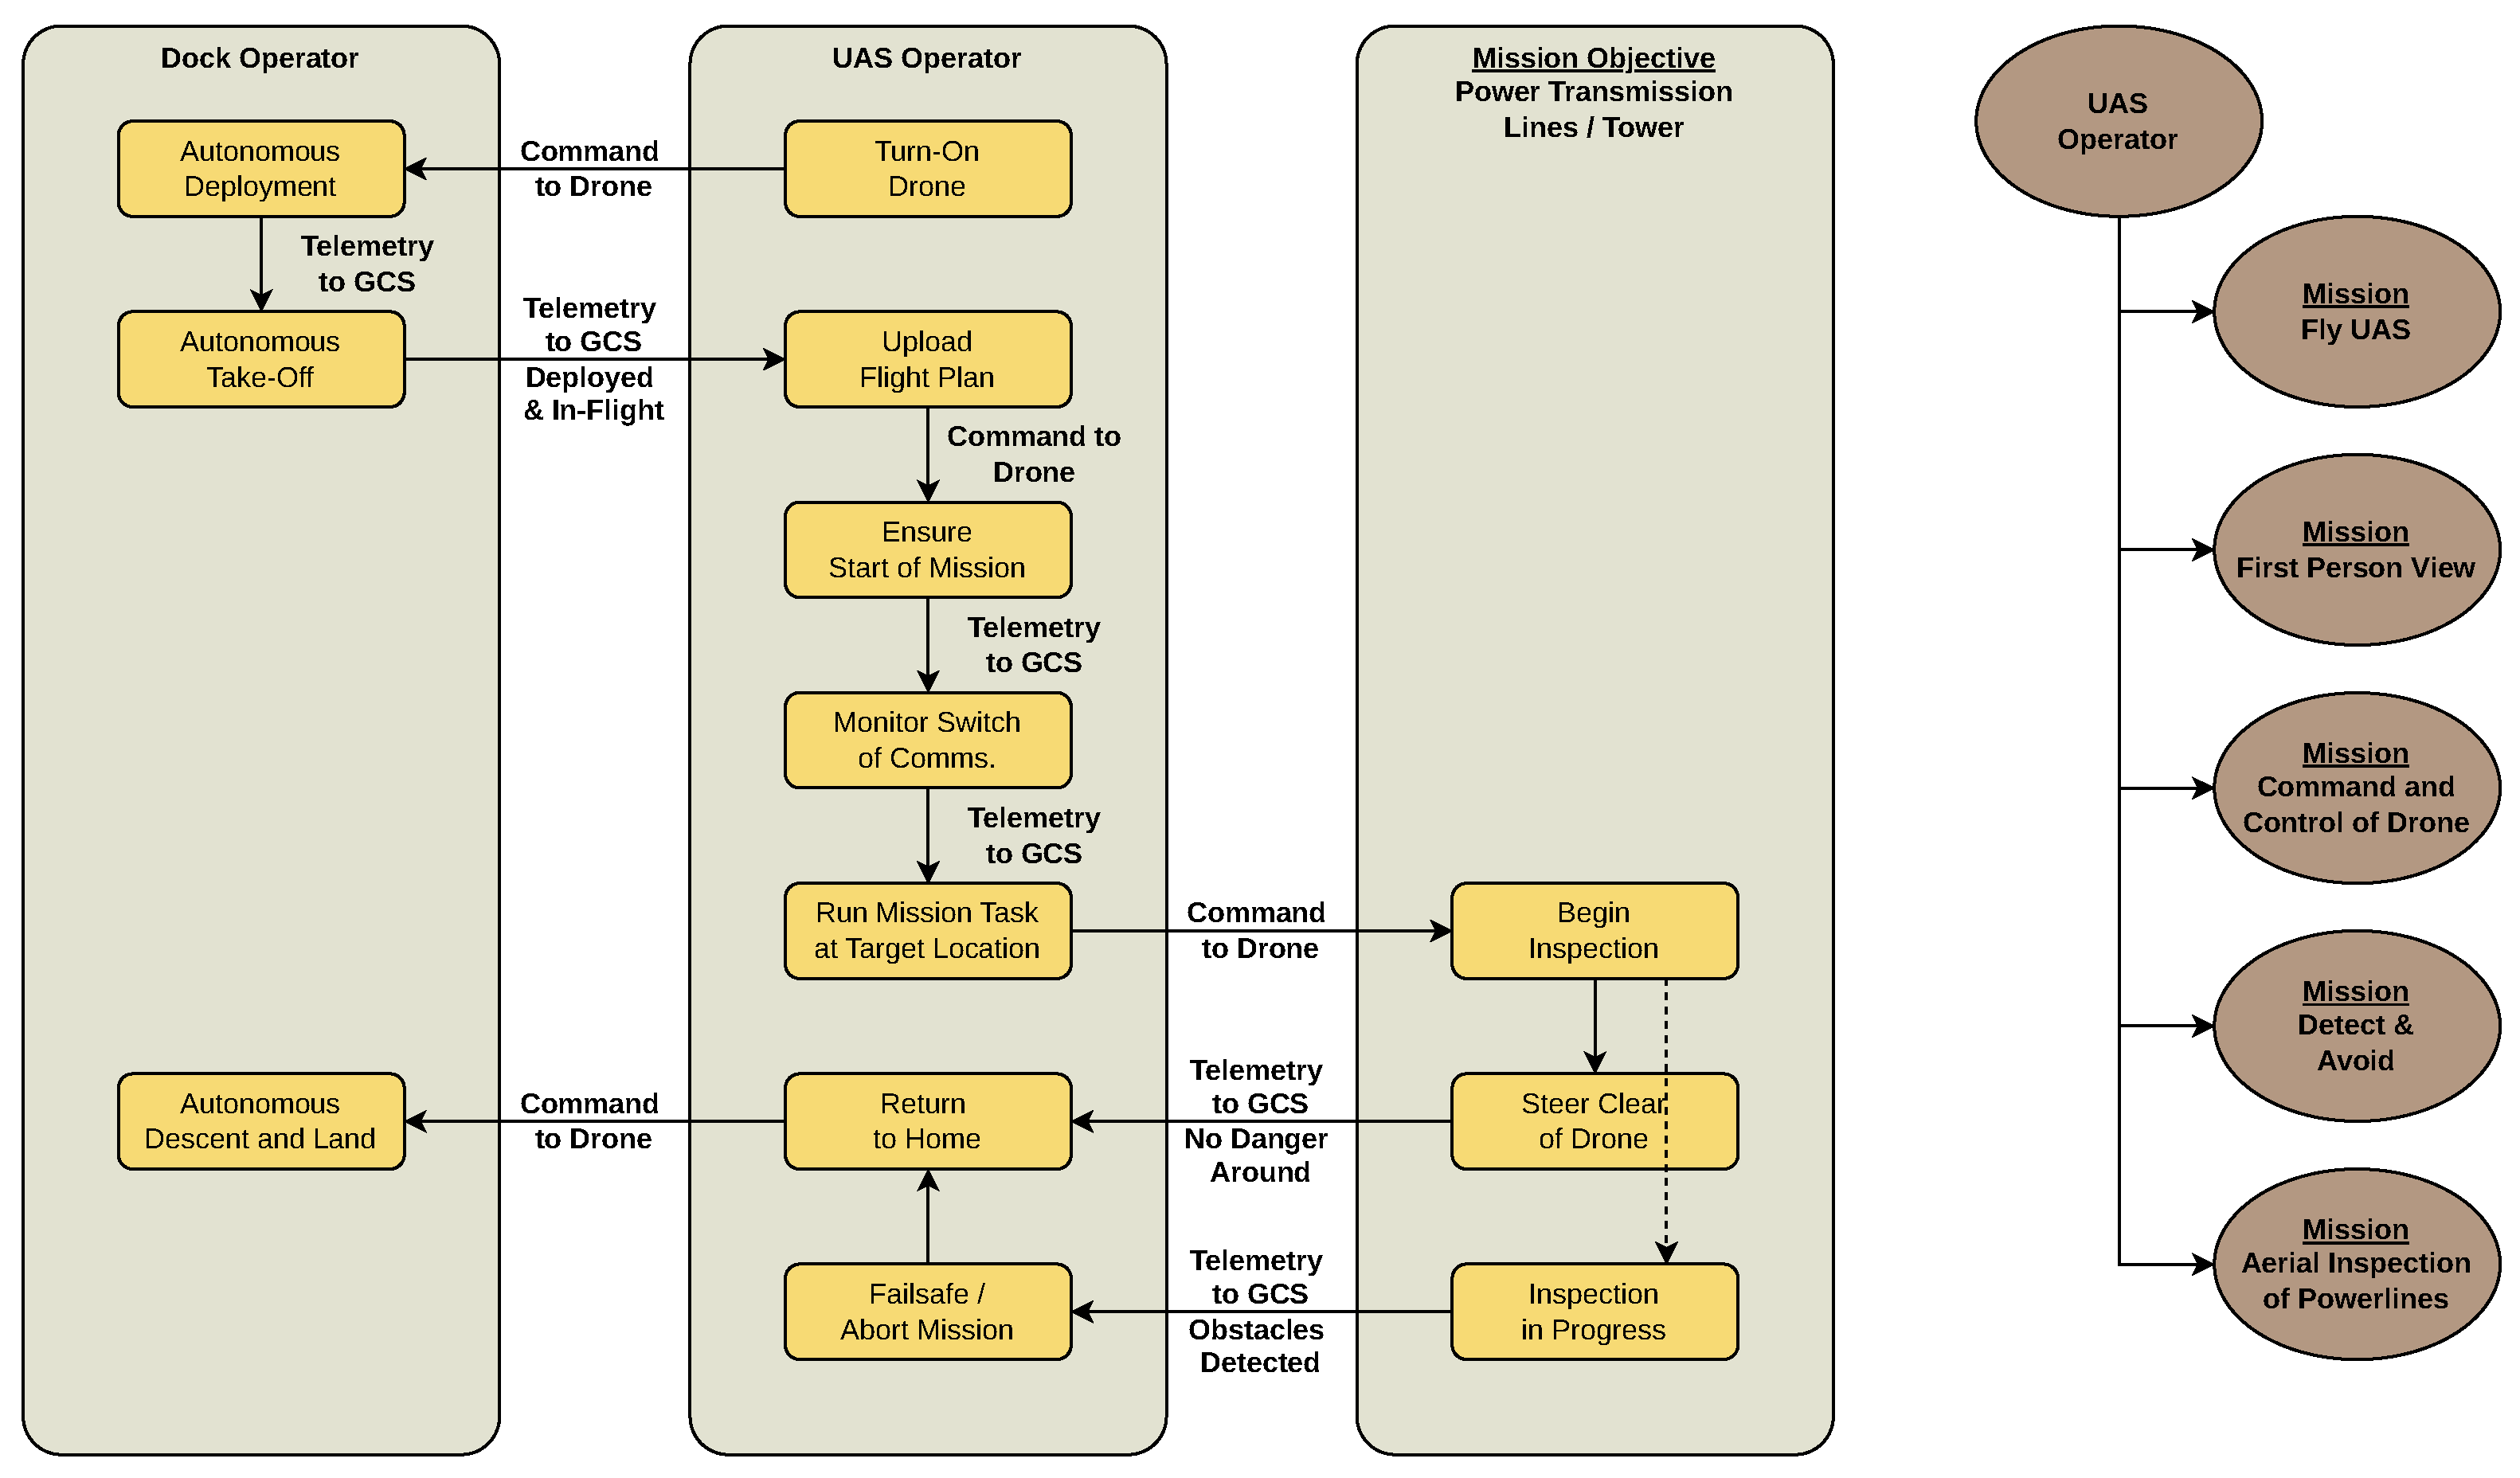
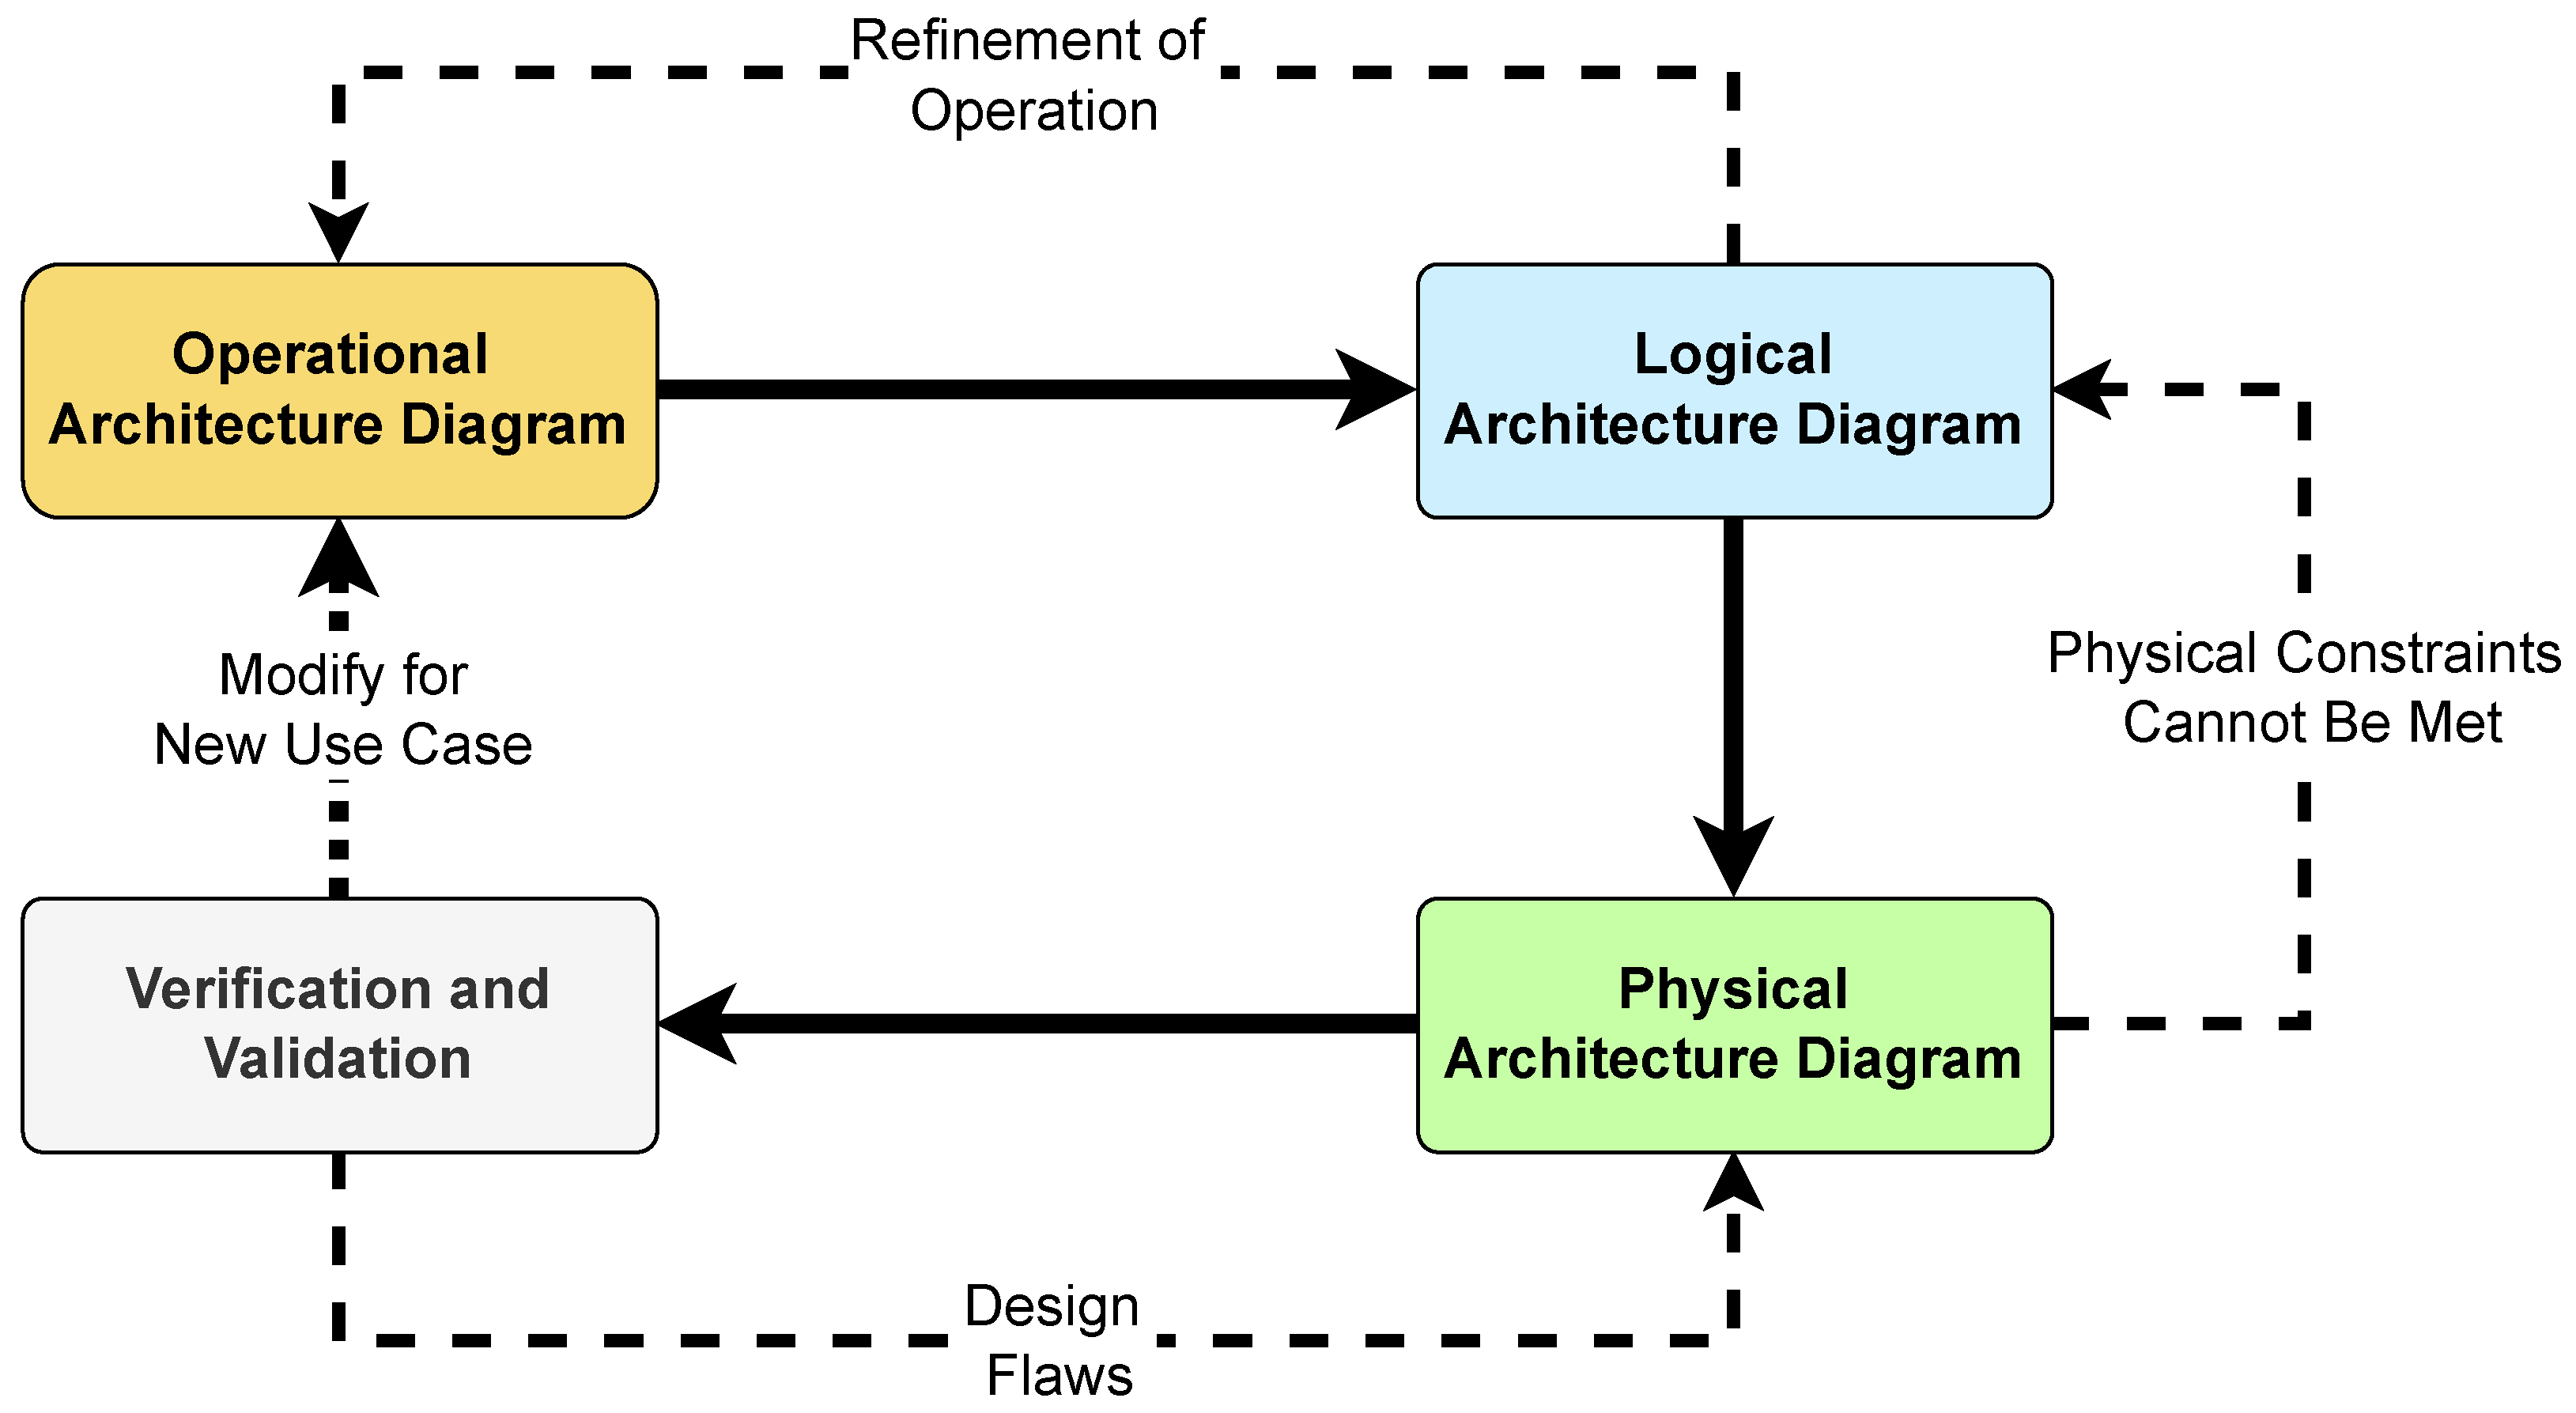
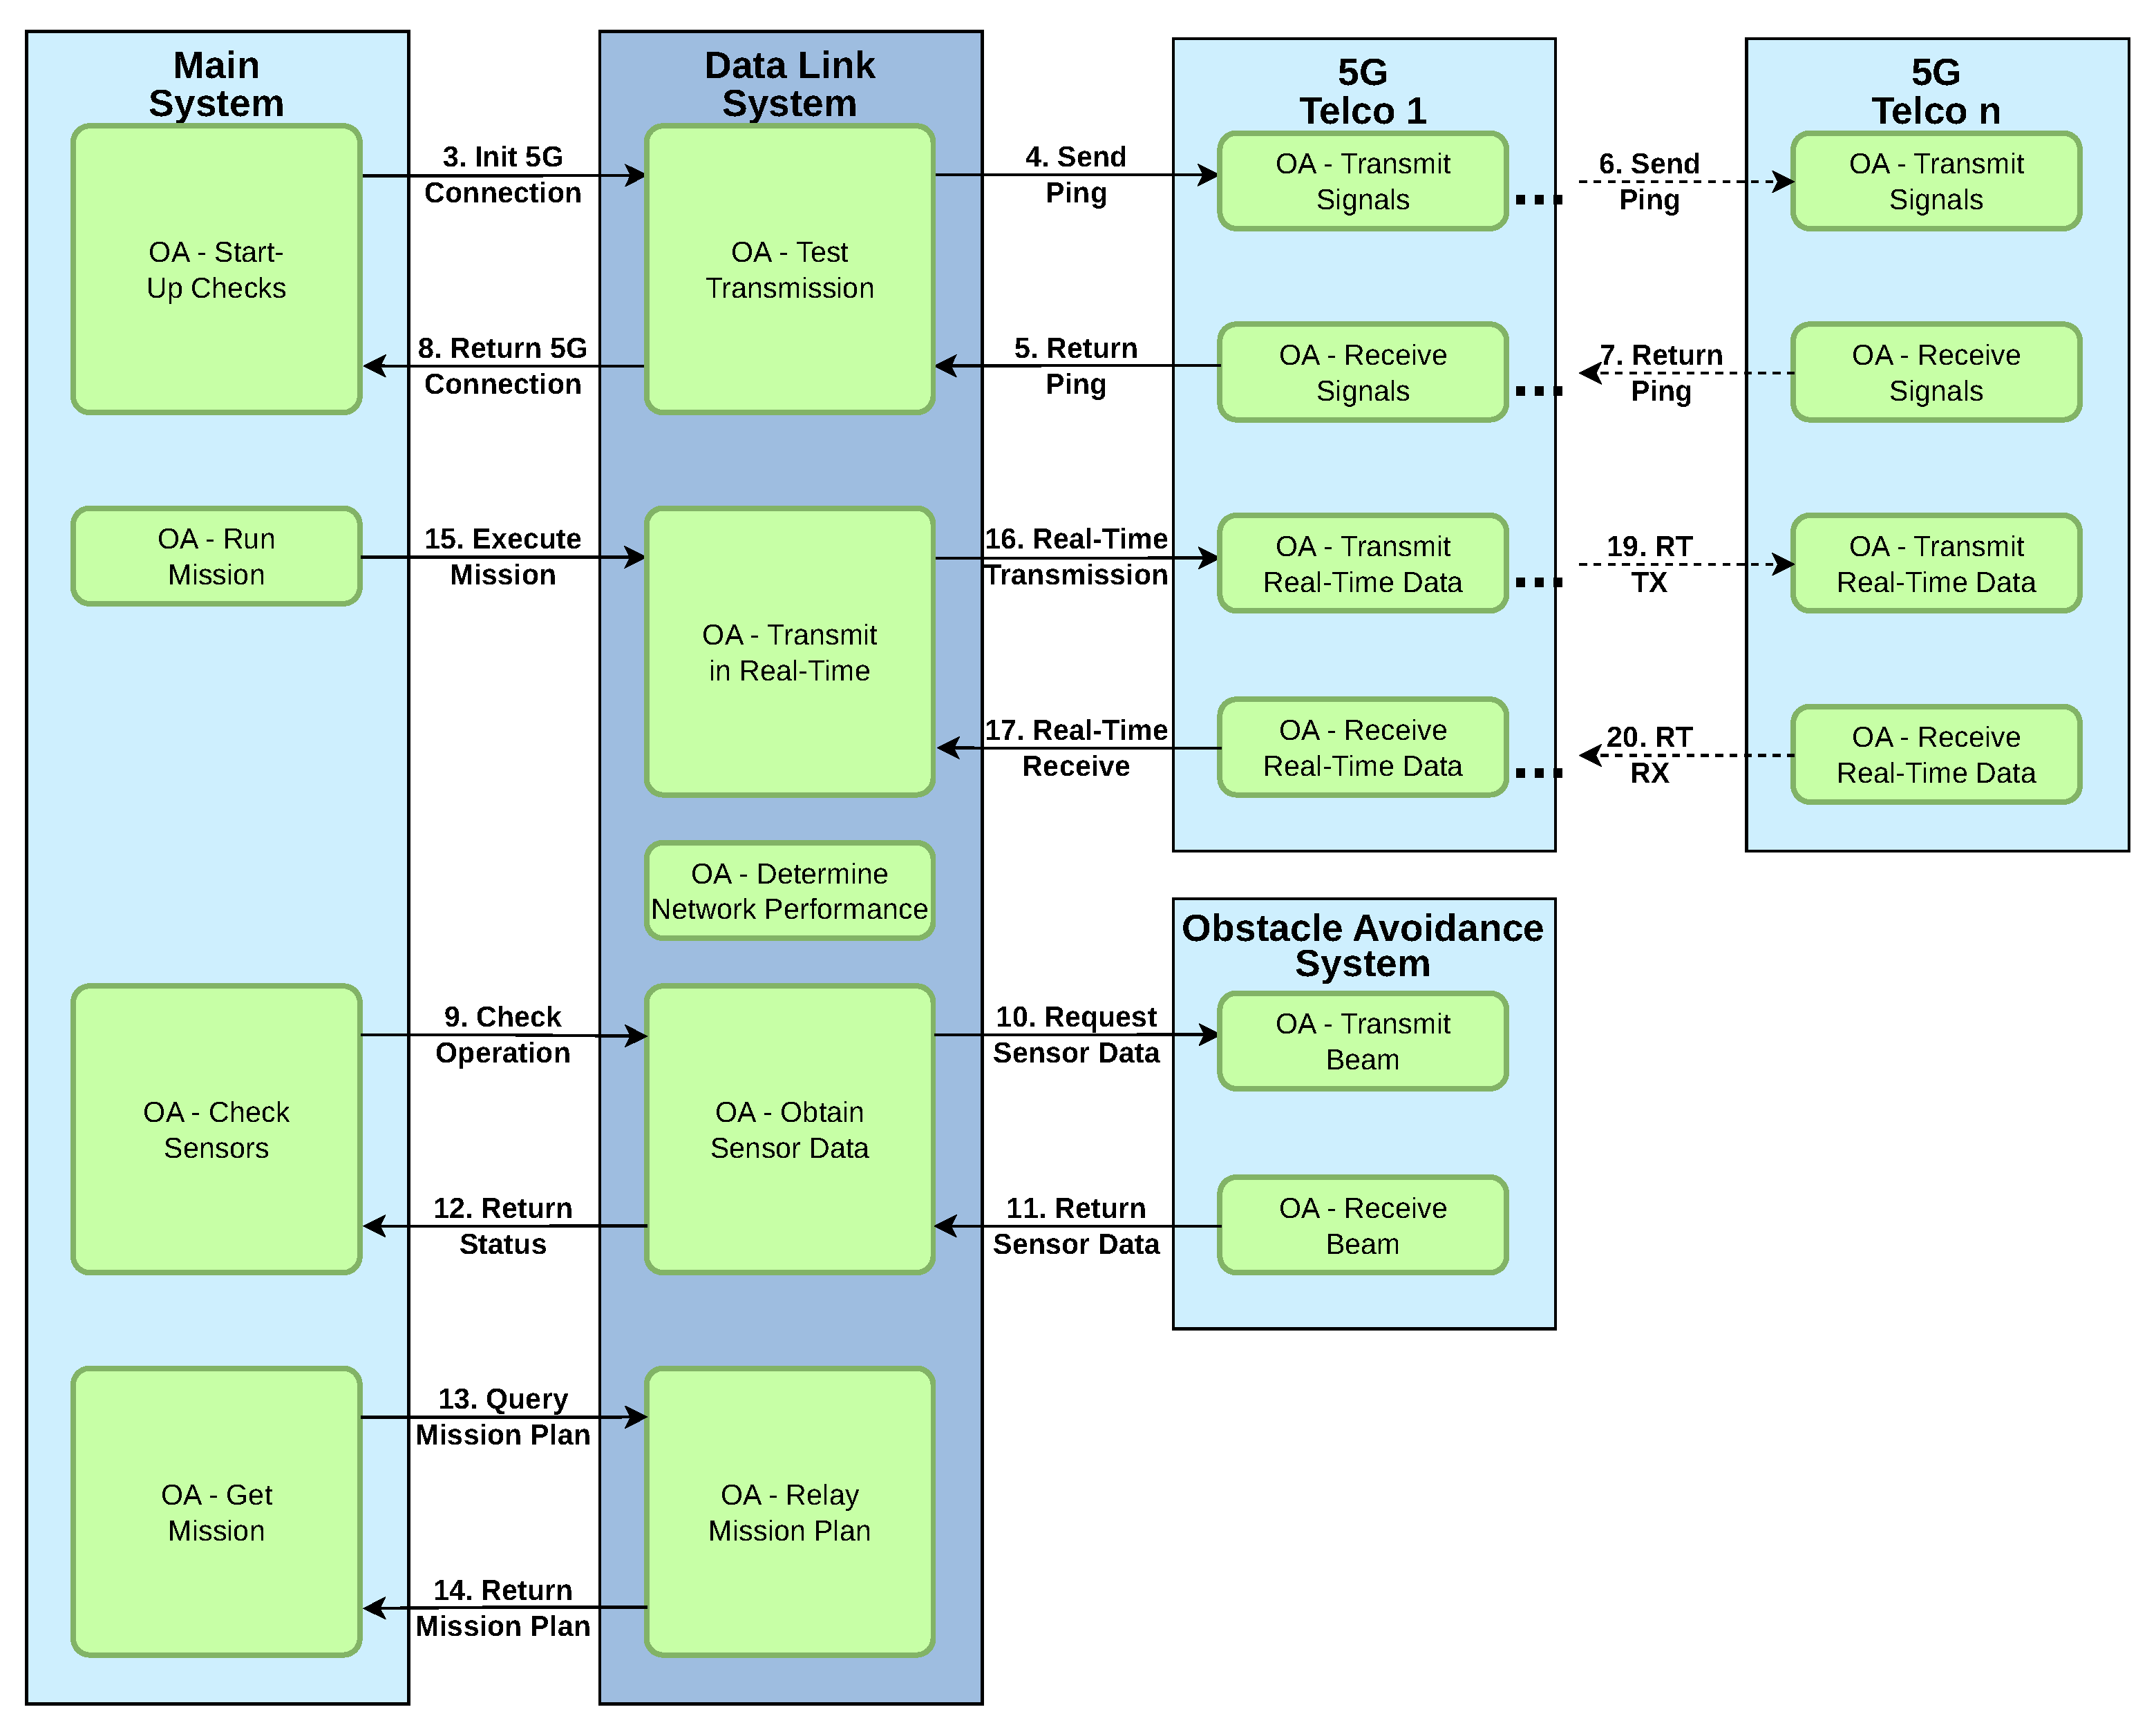
3.1. Operational Architecture Diagram
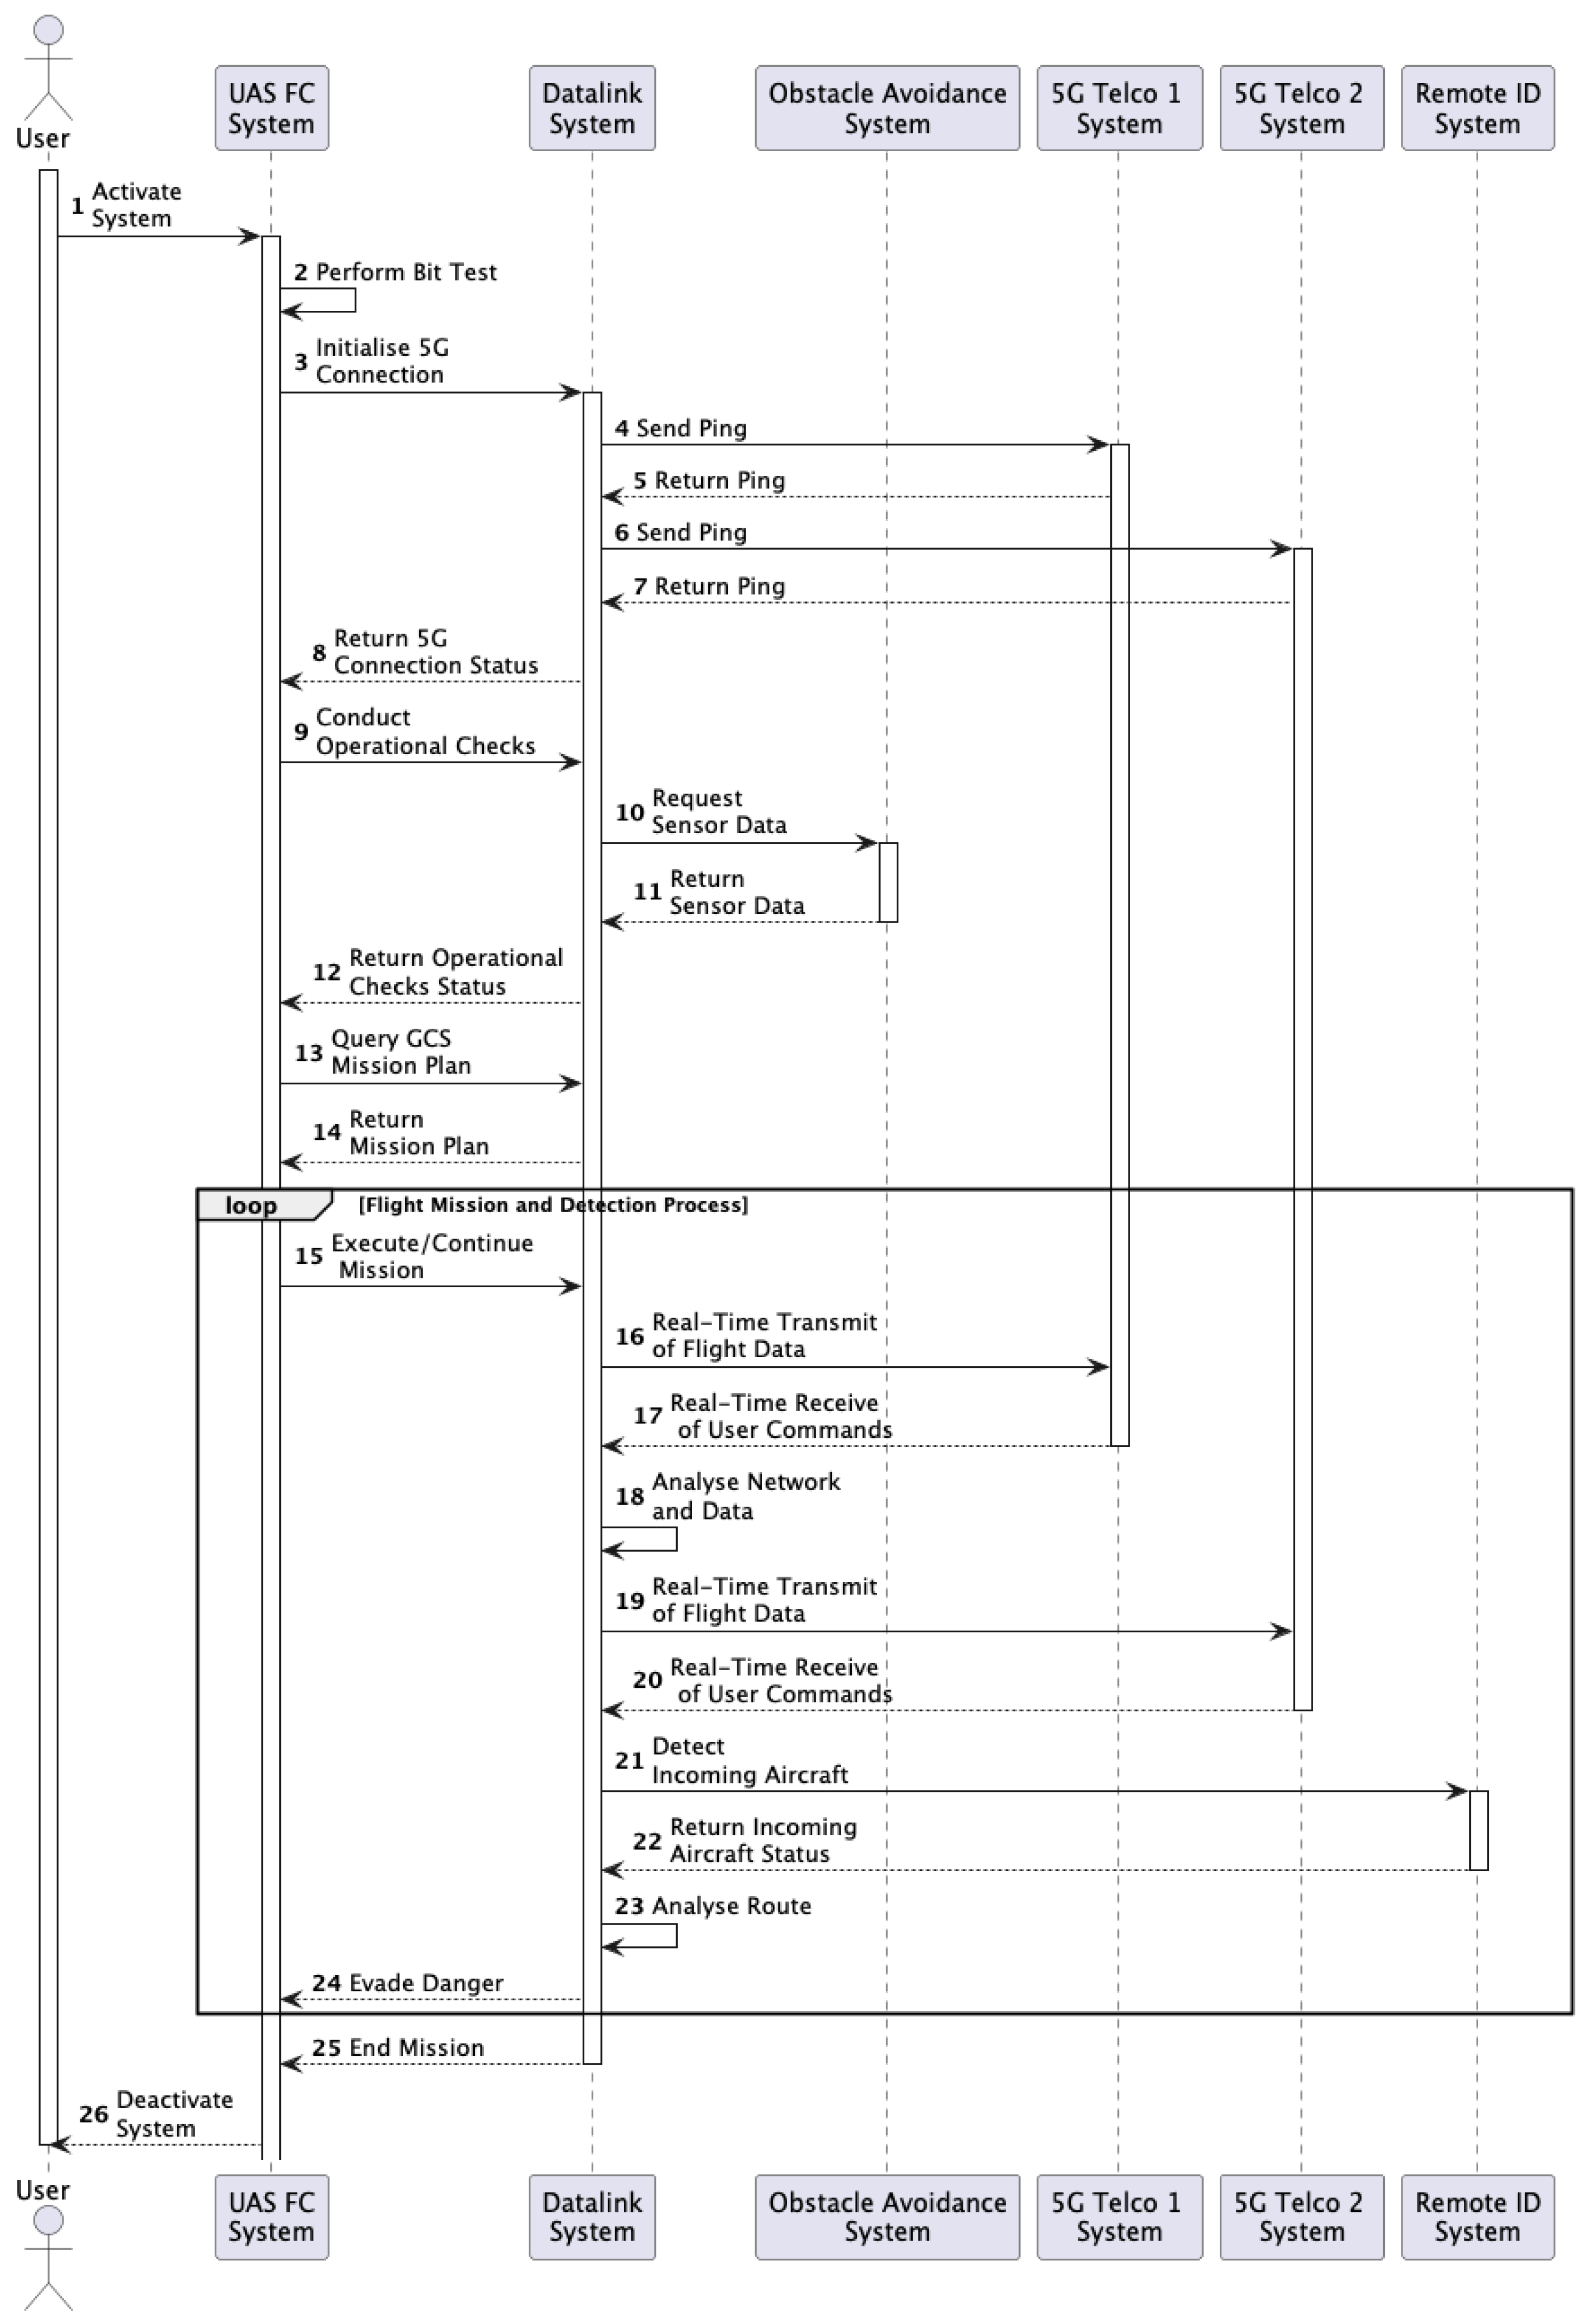
3.2. Logical Architecture Diagram
3.3. Physical Architecture Diagram
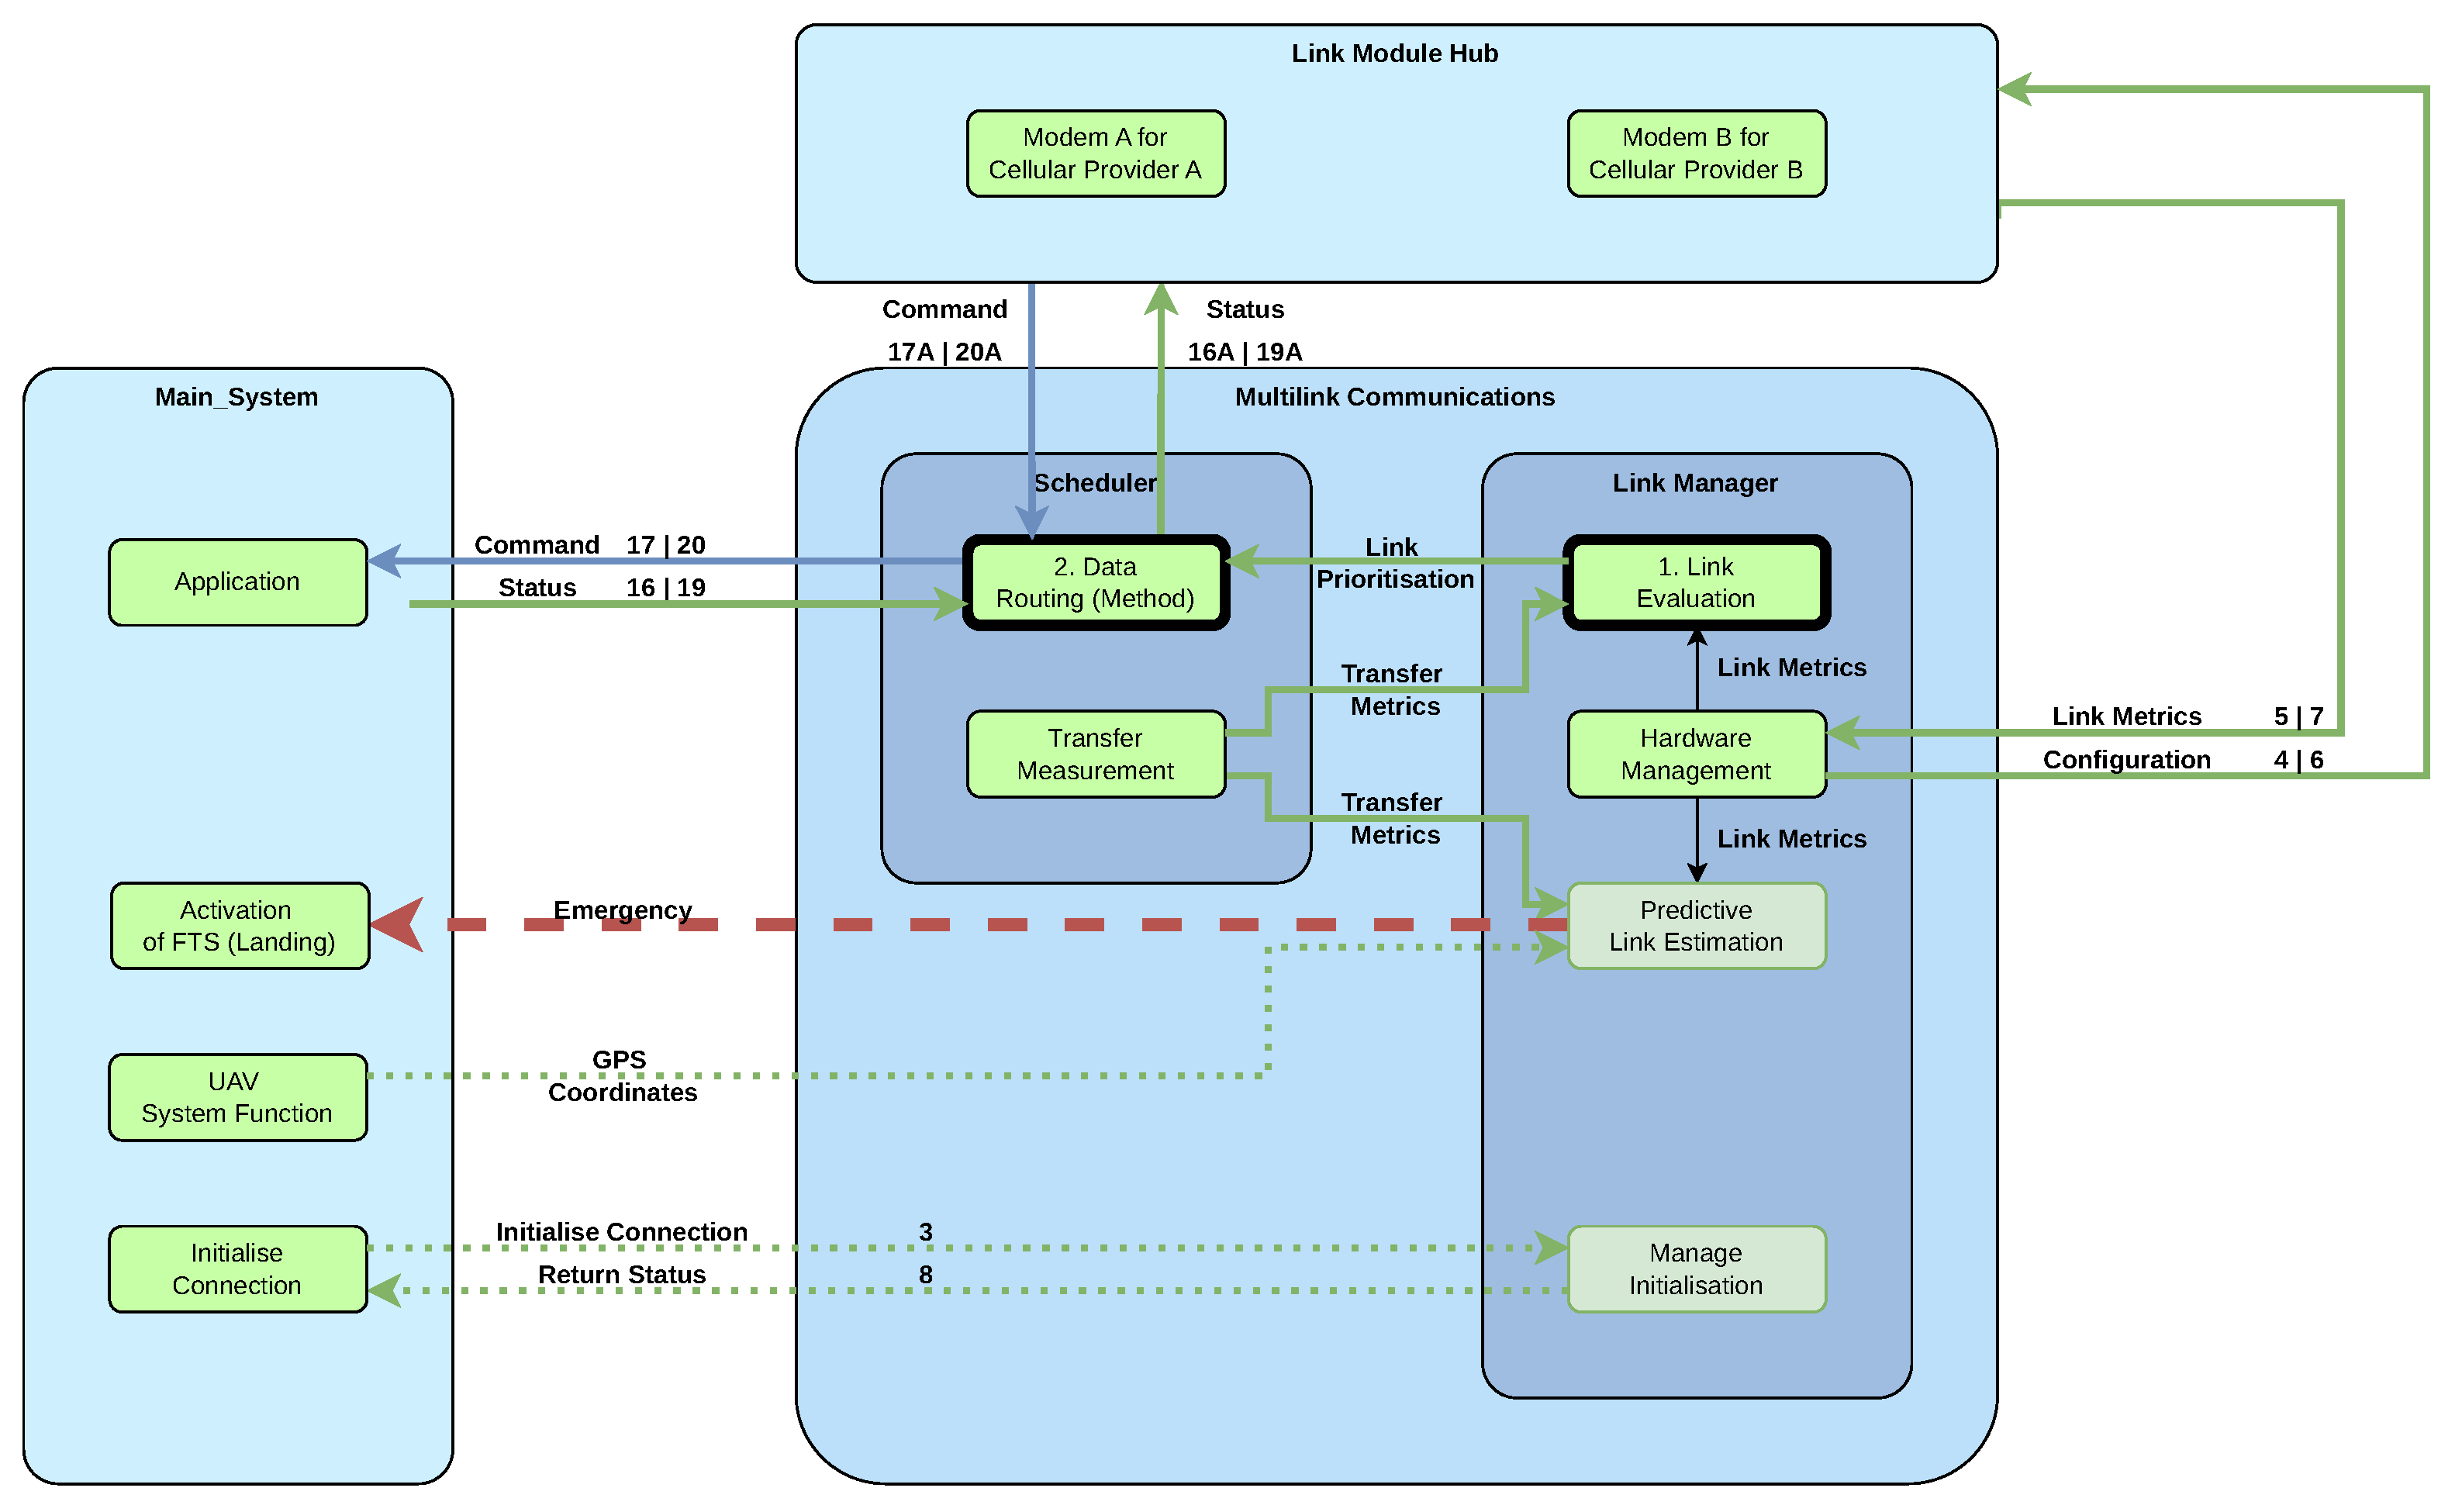
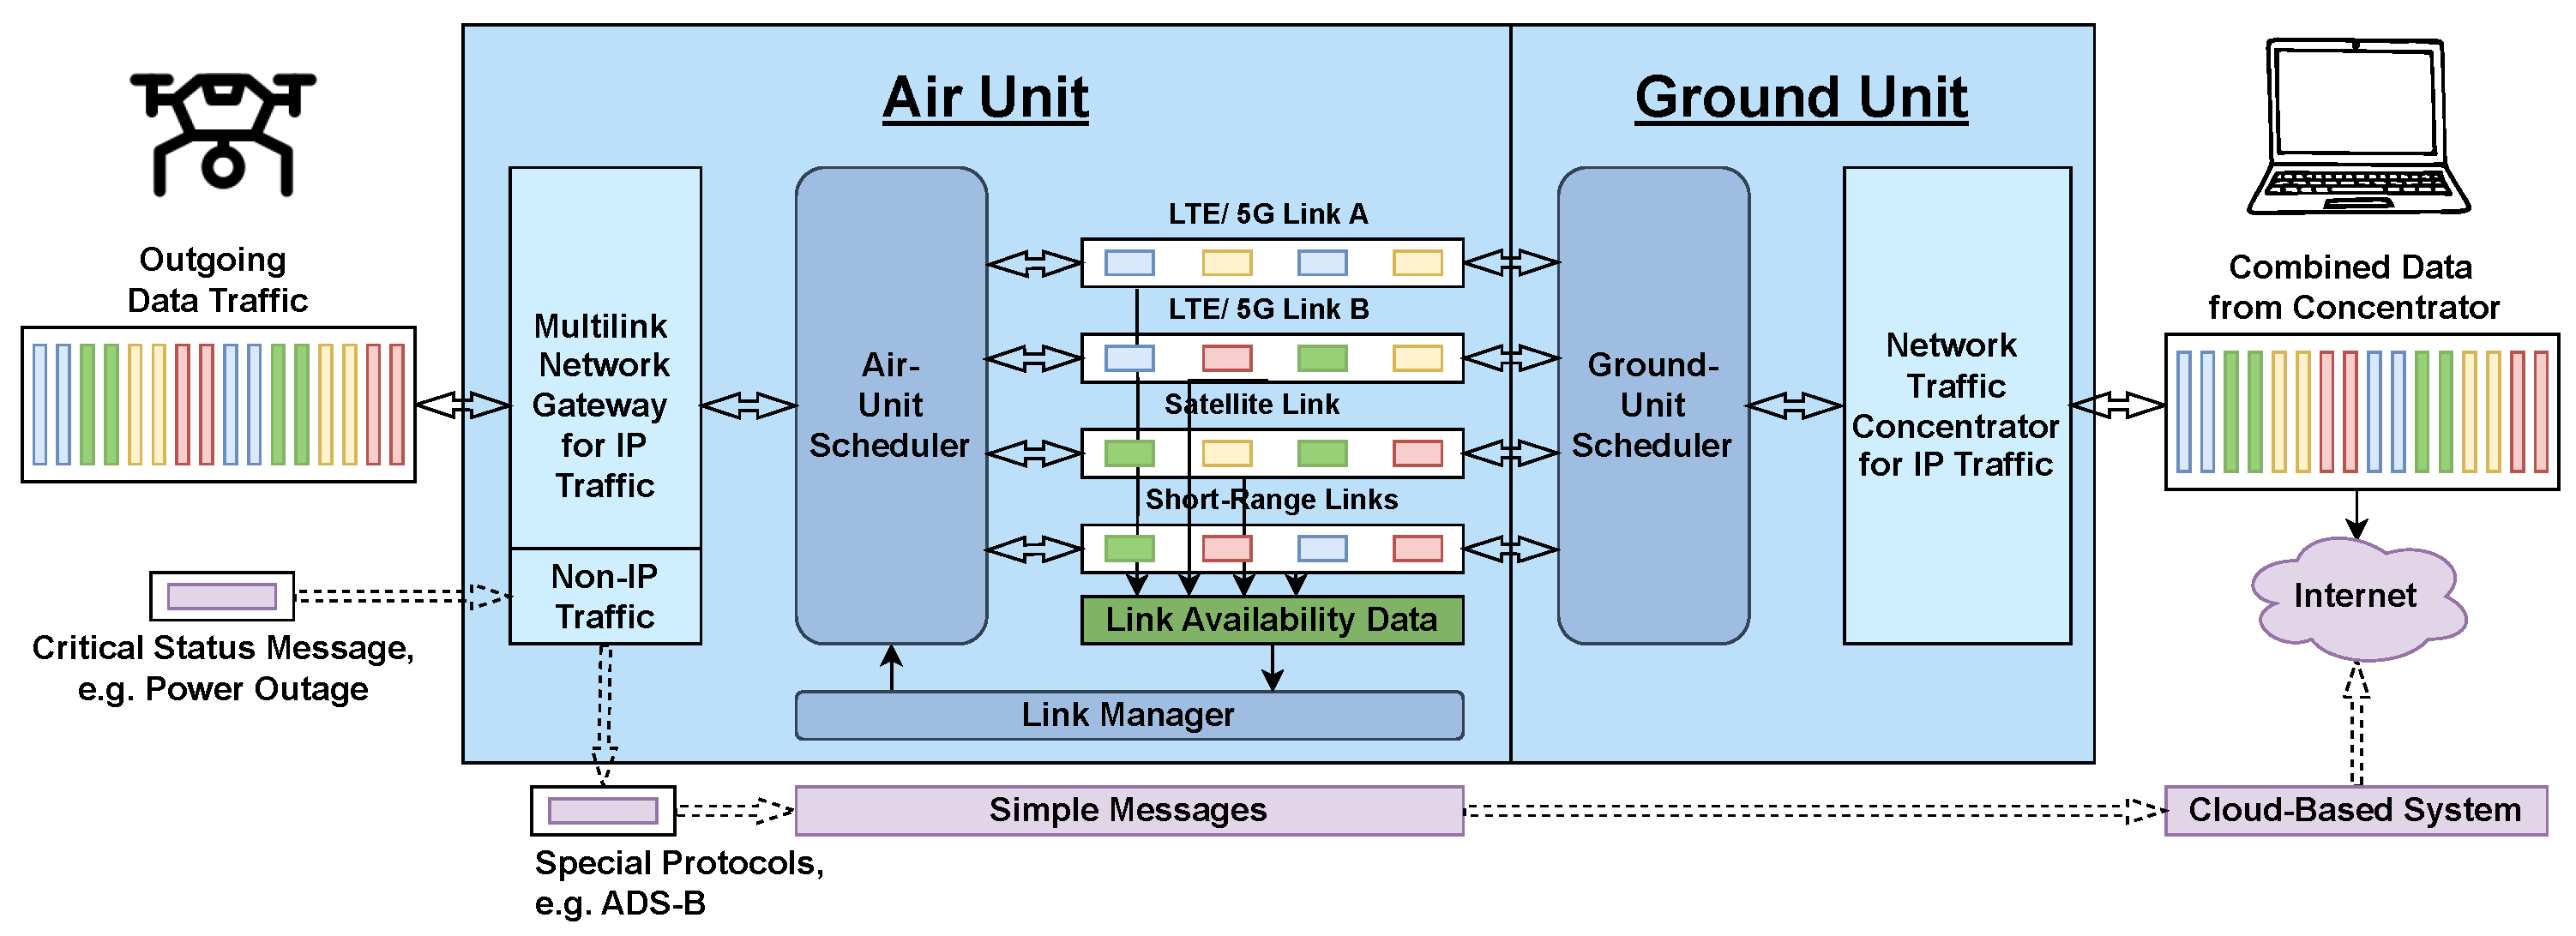
- Packet Distribution: Manages packet distribution and load balancing across available paths to optimize data throughput.
- Transfer Measurement: Monitors data-transfer performance to support efficient path-utilization decisions.
- Link Evaluation: Assesses real-time link metrics to prioritize the most reliable communication paths.
- Hardware Management: Configures modem settings and manages physical resources.
- Predictive Link Estimation (future software add-on): Anticipates link conditions to maintain stable connection.
- Manage Initialization (future software add-on): Handles the coordination of the boot-up sequence between the main system and the C2 data-link system when intricate startup management is needed.
4. Test Results for Bandwidth and Latency
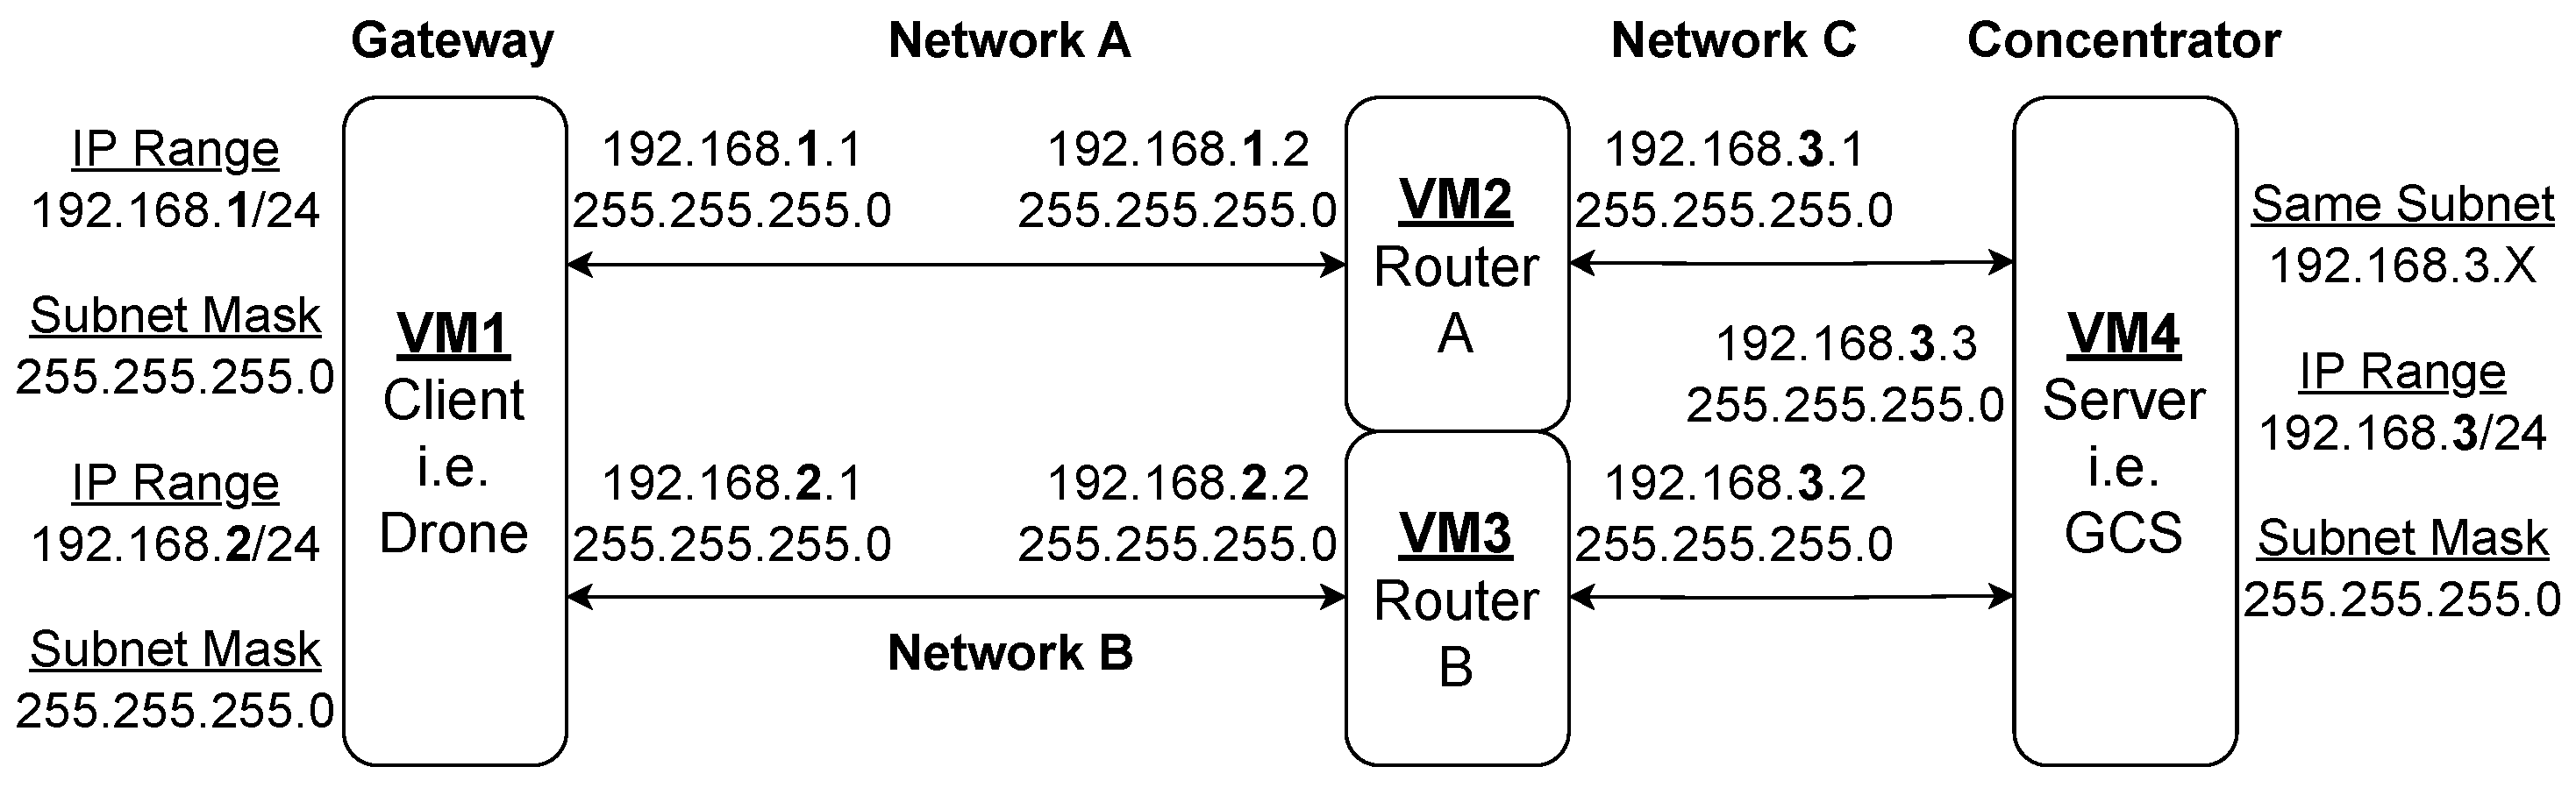
4.1. Test Setup for Bandwidth
| Listing 1: iPerf3 command example. |
| iperf3 -c <server_IP_address> -B <client_IP_address> -t 10 |
4.2. Results for Bandwidth
4.3. Test Setup for Latency
| Listing 2: Ping command example. |
| ping -c 100 <server_IP_address> |
4.4. Results for Latency
| Listing 3: Interface Status Log and Failover Trigger. |
| 2025-08-05 23:02:48 - enp60s0 is UP (CABLE CONNECTED) |
| 2025-08-05 23:02:49 - enp60s0 is UP (CABLE CONNECTED) |
| 2025-08-05 23:02:50 - enp60s0 is UP (CABLE CONNECTED) |
| 2025-08-05 23:02:51 - enp60s0 is UP (CABLE DISCONNECTED) |
| DEBUG: Cable disconnect detected! Triggering failover... |
| Listing 4: Failover Completion Time. |
| Failover completed in 0.116455208 s |
| Listing 5: Ping Test Output to 10.0.0.1. |
| 2. Testing connectivity to 10.0.0.1: |
| PING 10.0.0.1 (10.0.0.1) 56(84) bytes of data. |
| 64 bytes from 10.0.0.1: icmp_seq=1 ttl=64 time=9.41 ms |
| 64 bytes from 10.0.0.1: icmp_seq=2 ttl=64 time=65.6 ms |
| 64 bytes from 10.0.0.1: icmp_seq=3 ttl=64 time=87.2 ms |
| --- 10.0.0.1 ping statistics --- |
| 3 packets transmitted, 3 received, 0% packet loss, time 2003 ms |
| rtt min/avg/max/mdev = 9.409/54.088/87.221/32.799 ms |
4.5. Validation of Results
4.6. Adapting C2 Data Link for New-Use Case
5. Conclusions
Author Contributions
Funding
Data Availability Statement
Conflicts of Interest
References
- Boedecker, H. Global Drone Industry Review 2025|Drone Industry Insights 2025; Technical Report; Drone Industry Insights: Hamburg, Germany, 2025. [Google Scholar]
- Alvarado, E. Global Drone Industry Review 2024|Drone Industry Insights 2025; Technical Report; Drone Industry Insights: Hamburg, Germany, 2024. [Google Scholar]
- Kay, W. The State of the Drone Industry 2025—Free White Paper|Drone Industry Insights 2025; Technical Report; Drone Industry Insights: Hamburg, Germany, 2025. [Google Scholar]
- Nikodem, F.; Rothe, D.; Dittrich, J.S. Operations Risk Based Concept for Specific Cargo Drone Operation in Low Altitudes. In Automated Low-Altitude Air Delivery: Towards Autonomous Cargo Transportation with Drones; Springer International Publishing: Cham, Switzerland, 2022; pp. 25–48. [Google Scholar] [CrossRef] [Scilit]
- Habibi, H.; Rao, D.M.K.K.V.; Sanchez-Lopez, J.L.; Voos, H. On SORA for High-Risk UAV Operations under New EU Regulations: Perspectives for Automated Approach. arXiv 2023. [Google Scholar] [CrossRef] [Scilit]
- Martinez, C.; Sanchez-Cuevas, P.J.; Gerasimou, S.; Bera, A.; Olivares-Mendez, M.A. SORA Methodology for Multi-UAS Airframe Inspections in an Airport. Drones 2021, 5, 141. [Google Scholar] [CrossRef] [Scilit]
- Politi, E.; Varlamis, I.; Tserpes, K.; Larsen, M.; Dimitrakopoulos, G. The future of safe BVLOS drone operations with respect to system and service engineering. In 2022 IEEE International Conference on Service-Oriented System Engineering (SOSE); IEEE: New York, NY, USA, 2022; pp. 133–140. [Google Scholar]
- Terkildsen, K.H.; Jensen, K. Towards a Tool for Assessing UAS Compliance with the JARUS SORA Guidelines. In 2019 International Conference on Unmanned Aircraft Systems (ICUAS); IEEE: New York, NY, USA, 2019; pp. 460–466. [Google Scholar]
- Rothe, D.; Nikodem, F. System Architectures and Its Development Efforts Based on Different Risk Classifications. In Automated Low-Altitude Air Delivery: Towards Autonomous Cargo Transportation with Drones; Springer International Publishing: Cham, Switzerland, 2022; pp. 263–288. [Google Scholar] [CrossRef] [Scilit]
- Rakotonarivo, B.; Drougard, N.; Conversy, S.; Garcia, J. Supporting drone mission planning and risk assessment with interactive representations of operational parameters. In 2022 International Conference on Unmanned Aircraft Systems (ICUAS); IEEE: New York, NY, USA, 2022; pp. 1091–1100. [Google Scholar]
- European Union Aviation Safety Agency (EASA). Drone Operations in EASA Member States—Statistics and Key; Information from Your Member State|EASA; EASA: Cologne, Germany, 2025. [Google Scholar]
- Janke, C.; de Haag, M.U. Implementation of European Drone Regulations - Status Quo and Assessment. J. Intell. Robot. Syst. 2022, 106, 33. [Google Scholar] [CrossRef] [Scilit]
- European Union Aviation Safety Agency (EASA). Specific Operations Risk Assessment (SORA); EASA: Cologne, Germany, 2023. [Google Scholar]
- Ministerie van Infrastructuur en Waterstaat. Technische Eisen Dronecategorie Specifiek; Ministerie van Infrastructuur en Waterstaat: The Hague, The Netherlands, 2025. [Google Scholar]
- Schalk, L.M.; Becker, D. Data Link Concept for Unmanned Aircraft in the Context of Operational Risk. In Automated Low-Altitude Air Delivery: Towards Autonomous Cargo Transportation with Drones; Springer International Publishing: Cham, Switzerland, 2022; pp. 303–332. [Google Scholar] [CrossRef] [Scilit]
- Badra, A.A.; Aïello, O.; Chaudemar, J.C. Applying a Model-Based Systems Engineering Approach to Model an Unmanned Aerial Vehicle Mission. In 2023 IEEE International Systems Conference (SysCon); IEEE: New York, NY, USA, 2023; pp. 1–7. [Google Scholar] [CrossRef] [Scilit]
- Peinecke, N.; Muhlhausen, T. Cargo Drone Airspace Integration in Very Low Level Altitude. In Automated Low-Altitude Air Delivery: Towards Autonomous Cargo Transportation with Drones; Springer International Publishing: Cham, Switzerland, 2022; pp. 247–262. [Google Scholar] [CrossRef] [Scilit]
- Tsotra, A. Critical Comparative Analysis of UAS Legislative Developments. ISPRS Ann. Photogramm. Remote Sens. Spat. Inf. Sci. 2024, X-4/W4-2024, 223–230. [Google Scholar] [CrossRef] [Scilit]
- Song, H.; Chung, J.M. Next-generation wireless communication technologies for improved disaster response and management. ETRI J. 2025, 47, 375–392. [Google Scholar] [CrossRef] [Scilit]
- Braunfelds, J.; Jakovels, G.; Murans, I.; Litvinenko, A.; Senkans, U.; Rumba, R.; Onzuls, A.; Valters, G.; Lidere, E.; Plone, E. Experimental Study on LTE Mobile Network Performance Parameters for Controlled Drone Flights. Sensors 2024, 24, 6615. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Kasurinen, T. LTE Mobile Network Technical Feasibility for Unmanned Aerial Vehicle BVLOS operations in a Rural Test Area. In Proceedings of the SESAR Innovations Days, Seville, Spain, 27–30 November 2023. [Google Scholar]
- Thangadorai, K.K.; Prakash, M.; Baddeley, M.; Pandey, A.; Sivalingam, K.M. Extending Boundaries with WiLong: A Field Study on Long-Range Wi-Fi Mesh Custom Solution. In 2024 IEEE 49th Conference on Local Computer Networks (LCN); IEEE: New York, NY, USA, 2024; pp. 1–9. [Google Scholar]
- Nagarajan, R.; Sixsmith, A. Policy Initiatives to Address the Challenges of an Older Population in the Workforce. Ageing Int. 2021, 48, 41–77. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Zomerdijk, W.; Gusain, D.; Palensky, P.; Cvetkovic, M. Open Data Based Model of the Dutch High-Voltage Power System. In 2022 IEEE PES Innovative Smart Grid Technologies Conference Europe (ISGT-Europe); IEEE: New York, NY, USA, 2022; pp. 1–6. [Google Scholar]
- Netherlands Aerospace Centre (NLR). Enabling Safe and Seamless Drone Operations; NLR: Amsterdam, The Netherlands, 2025. [Google Scholar]
- Lee, H.; Hwang, Y.M.; Lee, J.; Kim, N.W.; Ko, S.K. A Drone-Driven X-Ray Image-Based Diagnosis of Wind Turbine Blades for Reliable Operation of Wind Turbine. IEEE Access 2024, 12, 56141–56158. [Google Scholar] [CrossRef] [Scilit]
- Salma, V.; Schmehl, R. Operation Approval for Commercial Airborne Wind Energy Systems. Energies 2023, 16, 3264. [Google Scholar] [CrossRef] [Scilit]
- Tee, B.W.C.; Rajan, R.T.; Larsen, M. Achieving Coverage, Capacity and Quality in C2 Data Links for BVLOS UAS Operations. In Proceedings of the International Conference on Telecommunications (ICT), Thessaloniki, Greece, 20–22 May 2026. [Google Scholar]
- Finkhauser, J.; Larsen, M. Reliable Command, Control and Communication Links for Unmanned Aircraft Systems: Towards compliance of commercial drones. In DroneSE and RAPIDO ’21: Proceedings of the 2021 Drone Systems Engineering and Rapid Simulation and Performance Evaluation: Methods and Tools Proceedings; Association for Computing Machinery: New York, NY, USA, 2021. [Google Scholar] [CrossRef] [Scilit]
- ADACORSA Consortium. Airborne Data Collection on Resilient System Architectures (ADACORSA), ECSEL Joint Undertaking Grant Agreement No. 876019. Available online: https://cordis.europa.eu/project/id/876019 (accessed on 1 May 2026).






| Step | Description | Remarks |
|---|---|---|
| 1 | Concept of Operations (ConOps) Description | Gather all technical, operational, and system information necessary to assess the risks of the intended UAS operation. |
| 2 | Initial Ground Risk Class (GRC) | Assess intrinsic factors such as UAS weight. |
| 3 | Final GRC | Consider design aspects and mitigation measures to establish the final GRC. |
| 4 | Initial Air Risk Class (ARC) | Evaluate the initial air risk based on the characteristics of the airspace. |
| 5 | Residual ARC | Assess residual air risk after applying strategic mitigation. |
| 6 | Tactical Mitigation Performance Requirements (TMPR) | Manage any remaining mid-air collision risks. |
| 7 | Determine Specific Assurance Integrity Level (SAIL) | Based on ConOps, final GRC and residual ARC. |
| 8 | Determine Containment Requirements | Ensure that the target level of safety is achieved for ground and air risks. |
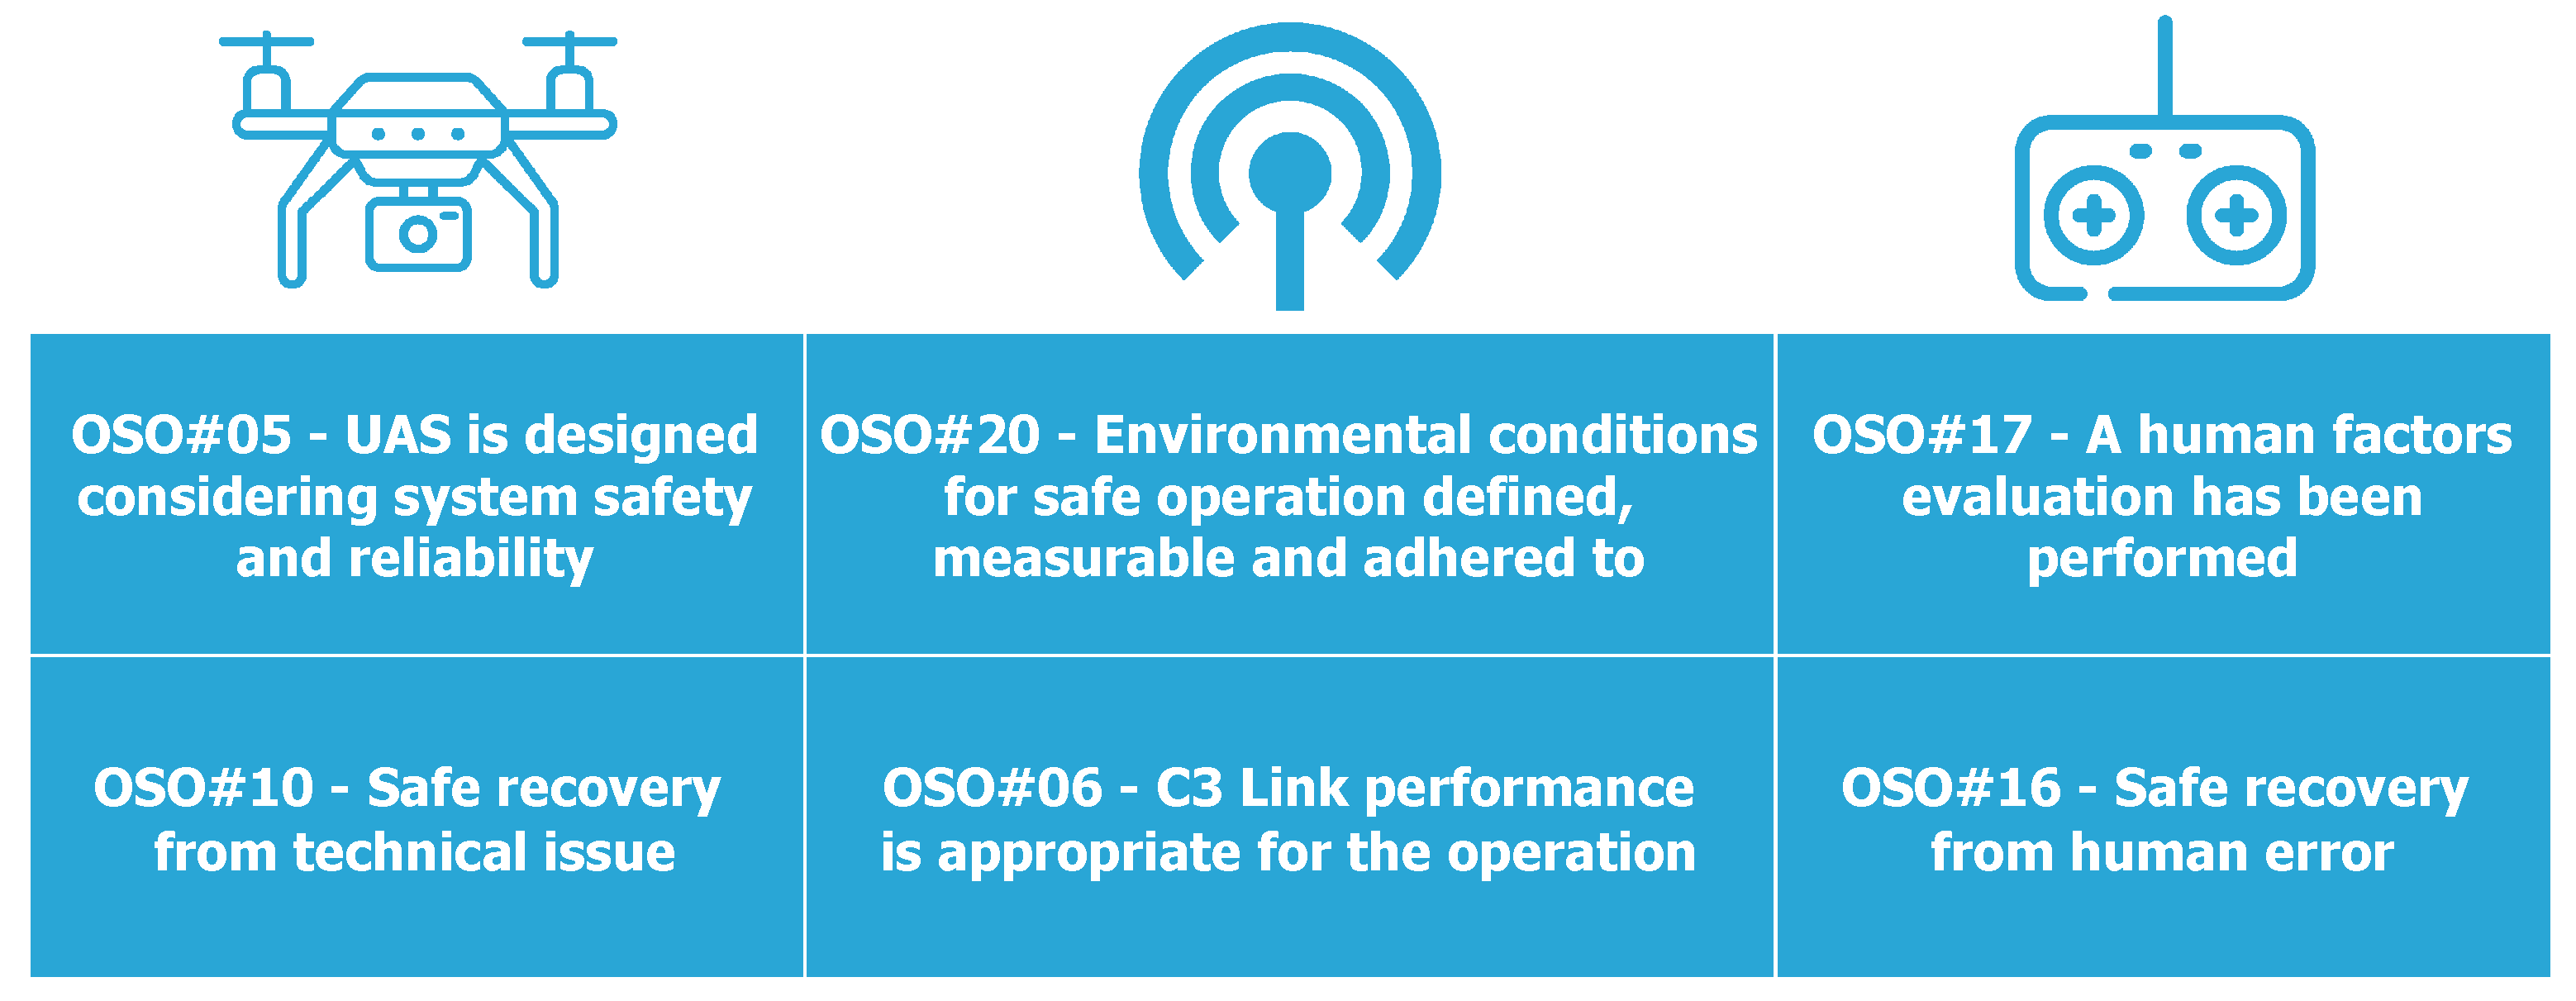
| 9 | Identify Operational Safety Objectives (OSO) | Demonstrate compliance with 24 OSOs at the required robustness levels. |
| 10 | Comprehensive Safety Portfolio | Demonstrate compliance with SORA regulations and document previous steps. |
| No. | Country | Organisation | Number of Registered Drone Operators | Number of OA | STS | A1/A2/A3 | STS/OA |
|---|---|---|---|---|---|---|---|
| 19 | Poland | Urząd Lotnictwa Cywilnego | 222,190 | 349 | 12,794 | 209,819 | 37 |
| 13 | Germany | Bundesministerium für Digitales und Verkehr (BMDV) | 694,000 | 289 | 11 | 346,600 | 0 |
| 20 | Czech Republic | Civil Aviation Authority of the Czech Republic | 54,782 | 272 | 0 | 60,636 | 0 |
| 10 | Netherlands | Human Environment and Transport Inspectorate | 66,228 | 245 | 330 | 7274 | 1 |
| 14 | France | Cabinets ministériels | 117,598 | 195 | 0 | 47,389 | 0 |
| 2 | Norway | CAA Norway | 23,660 | 167 | 215 | 34,513 | 1 |
| 5 | Denmark | Trafikstyrelsen—Droner | 8315 | 121 | 1511 | 32,185 | 12 |
| 4 | Finland | Finnish Transport and Communications Agency Traficom | 17,600 | 91 | 10 | 27,500 | 0 |
| 9 | Ireland | Irish Aviation Authority | 6451 | 66 | 546 | 19,238 | 8 |
| 24 | Slovenia | Civil Aviation Agency Slovenia | 5763 | 64 | 159 | 5454 | 2 |
| 17 | Spain | AESA | 94,033 | 46 | 43,255 | 140,432 | 940 |
| 21 | Austria | Austro Control | 51,978 | 44 | 0 | 76,262 | 0 |
| 28 | Greece | - | 11,350 | 42 | 0 | 16,210 | 0 |
| 15 | Switzerland | Federal Office of Civil Aviation FOCA | 67,200 | 33 | 5 | 61,331 | 0 |
| 23 | Hungary | Légügyi Kockázatértékelési Hatósági Főosztály | 4603 | 31 | 0 | 3752 | 0 |
| 3 | Sweden | Transport Styrelsen | 39,035 | 29 | 0 | 57,394 | 0 |
| 18 | Italy | Italian Civil Aviation Authority | 110,518 | 22 | 0 | 37,234 | 0 |
| 26 | Romania | - | 14,710 | 21 | 8989 | 8989 | 428 |
| 8 | Lithuania | Lietuvos Respublikos Seimo kanceliarija, biudžetinė įstaiga | 5583 | 19 | 397 | 4093 | 21 |
| 6 | Estonia | Estonian Transport Administration | 2976 | 15 | 10 | 4845 | 1 |
| 16 | Portugal | ANAC—Autoridade Nacional da Aviação Civil | 11,460 | 12 | 0 | 4488 | 0 |
| 25 | Croatia | Croatian Civil Aviation Agency | 2628 | 11 | 0 | 6545 | 0 |
| 7 | Latvia | Civilās aviācijas aģentūra | 4391 | 10 | 49 | 6696 | 5 |
| 11 | Belgium | FOD Mobiliteit en Vervoer | 23,112 | 8 | 0 | 18,966 | 0 |
| 12 | Luxembourg | Direction de l’Aviation Civile | 3063 | 4 | 0 | 94,362 | 0 |
| 27 | Bulgaria | Directorate General “Civil Aviation Administration” | 3361 | 1 | 0 | 2642 | 0 |
| 1 | Iceland | The Icelandic Transport Authority | 1562 | 0 | 0 | 930 | 0 |
| 22 | Slovakia | Transport Authority | 858 | 0 | 0 | 100 | 0 |
| Metric | Original Scheduler Software | Modified Scheduler Software | Change |
|---|---|---|---|
| Total Data Transmitted | 0.92 MBytes | 2.01 MBytes | +118% |
| Data Received by GCS | 0.38 MBytes | 1.65 MBytes | +334% |
| Delivery Success Rate | 41.72% | 82.09% | +96.7% |
| Interval | Transfer | Bitrate | Retransmissions (Retr) | Congestion Window (Cwnd) |
|---|---|---|---|---|
| 0.00–1.00 s | 76.4 KBytes | 625 Kbits/s | 0 | 32.5 KBytes |
| 1.00–2.00 s | 173 KBytes | 1.41 Mbits/s | 0 | 42.4 KBytes |
| 2.00–3.00 s | 0.00 Bytes | 0.00 bits/s | 0 | 43.8 KBytes |
| 3.00–4.00 s | 96.2 KBytes | 788 Kbits/s | 0 | 48.1 KBytes |
| 4.00–5.00 s | 127 KBytes | 1.04 Mbits/s | 0 | 59.4 KBytes |
| 5.00–6.00 s | 191 KBytes | 1.56 Mbits/s | 0 | 79.2 KBytes |
| 6.00–7.00 s | 0.00 Bytes | 0.00 bits/s | 0 | 97.6 KBytes |
| 7.00–8.00 s | 255 KBytes | 2.09 Mbits/s | 0 | 117 KBytes |
| 8.00–9.00 s | 0.00 Bytes | 0.00 bits/s | 3 | 117 KBytes |
| 9.00–10.00 s | 0.00 Bytes | 0.00 bits/s | 14 | 83.4 KBytes |
| 0.00–10.00 s | 918 KBytes | 752 Kbits/s | 17 | Sender |
| 0.00–11.95 s | 383 KBytes | 263 Kbits/s | Receiver |
| Interval | Transfer | Bitrate | Retransmissions (Retr) | Congestion Window (Cwnd) |
|---|---|---|---|---|
| 0.00–1.00 s | 341 KBytes | 2.79 Mbits/s | 0 | 45.2 KBytes |
| 1.00–2.00 s | 255 KBytes | 2.09 Mbits/s | 0 | 53.7 KBytes |
| 2.00–3.00 s | 127 KBytes | 1.04 Mbits/s | 0 | 62.2 KBytes |
| 3.00–4.00 s | 191 KBytes | 1.56 Mbits/s | 0 | 70.7 KBytes |
| 4.00–5.00 s | 382 KBytes | 3.13 Mbits/s | 0 | 87.7 KBytes |
| 5.00–6.00 s | 0.00 Bytes | 0.00 bits/s | 12 | 74.9 KBytes |
| 6.00–7.00 s | 255 KBytes | 2.09 Mbits/s | 6 | 80.6 KBytes |
| 7.00–8.00 s | 255 KBytes | 2.09 Mbits/s | 0 | 94.7 KBytes |
| 8.00–9.00 s | 255 KBytes | 2.09 Mbits/s | 9 | 65.0 KBytes |
| 9.00–10.00 s | 0.00 Bytes | 0.00 bits/s | 0 | 73.5 KBytes |
| 0.00–10.00 s | 2.01 MBytes | 1.69 Mbits/s | 27 | Sender |
| 0.00–10.46 s | 1.65 MBytes | 1.32 Mbits/s | – | Receiver |
Disclaimer/Publisher’s Note: The statements, opinions and data contained in all publications are solely those of the individual author(s) and contributor(s) and not of MDPI and/or the editor(s). MDPI and/or the editor(s) disclaim responsibility for any injury to people or property resulting from any ideas, methods, instructions or products referred to in the content. |
© 2026 by the authors. Licensee MDPI, Basel, Switzerland. This article is an open access article distributed under the terms and conditions of the Creative Commons Attribution (CC BY) license.
Share and Cite
Wei Cong, B.T.; Rajan, R.T.; Larsen, M. Designing C2 Links for BVLOS UAS Operations. Drones 2026, 10, 397. https://doi.org/10.3390/drones10060397
Wei Cong BT, Rajan RT, Larsen M. Designing C2 Links for BVLOS UAS Operations. Drones. 2026; 10(6):397. https://doi.org/10.3390/drones10060397
Chicago/Turabian StyleWei Cong, Barry Tee, Raj Thilak Rajan, and Morten Larsen. 2026. "Designing C2 Links for BVLOS UAS Operations" Drones 10, no. 6: 397. https://doi.org/10.3390/drones10060397
APA StyleWei Cong, B. T., Rajan, R. T., & Larsen, M. (2026). Designing C2 Links for BVLOS UAS Operations. Drones, 10(6), 397. https://doi.org/10.3390/drones10060397