


Abstract
The assignment of tasks for unmanned aerial vehicles (UAVs) during forest fire reconnaissance is a highly complex and large-scale problem. Current task allocation methods struggle to strike a balance between solution speed and effectiveness. In this paper, a two-phase centralized UAV task assignment model based on expectation maximization (EM) clustering and the multidimensional knapsack model (MKP) is proposed for the forest fire reconnaissance task assignment. The fire situation information is acquired using the sensors carried by satellites at first. Then, the EM algorithm based on the Gaussian mixture model (GMM) is applied to get the initial position of every UAV. In the end, the MKP is applied for UAV task assignment based on the initial positions of the UAVs. An improved genetic algorithm (GA) based on the fireworks algorithm (FWA) is proposed for faster iteration speed. A simulation was carried out against the background of forest fires in Liangshan Prefecture, Sichuan Province, and the simulation’s results demonstrate that the task assignment model can quickly and effectively address task allocation problems on a large scale. In addition, the FW–GA hybrid algorithm has great advantages over the traditional GA, particularly in solving time, iteration convergence speed, and solution effectiveness. It can reduce up to 556% of the iteration time and increase objective function value by 1.7% compared to the standard GA. Furthermore, compared to the GA–SA algorithm, its solving time is up to 60 times lower. This paper provides a new idea for future large-scale UAV task assignment problems.
Keywords:
UAV task assignment; gaussian mixture model; multidimensional 0-1 knapsack problem; improved genetic algorithm (GA); fireworks algorithm (FWA) MSC:
90C27
1. Introduction
Forest fires occur frequently due to global warming and human production activities in recent years. The vast fire areas, complex fire situations and dangerous environments make fire reconnaissance a worldwide problem. Only by sensing the fire situation and reasonably planning the deployment of emergency rescue forces can forest fire loss be minimized.
Unmanned aerial vehicles (UAVs) have been widely used in civilian or military fields in recent years. Owing to their high safety, superb flexibility and excellent vision, UAVs are widely used in dangerous reconnaissance missions including battlefield military reconnaissance and geological surveys of dangerous areas [1]. Because of the complexity and danger of forest fire reconnaissance missions, UAVs have become the best way to reconnoiter forest fires. UAVs have often been involved in rescues from and investigations of disaster areas in recent years. During the Fukushima nuclear leakage accident in Japan, the United States sent Global Hawk UAVs to investigate the nuclear leakage site.
Limited load and limited flying range limit the application of single UAVs. For overcoming the drawbacks of single UAVs, the concept of using multiple UAVs is proposed. A group of individual UAVs could carry different loads to perform special missions. Compared with single UAVs, a group of UAVs will perform the mission more efficiently, robustly and cheaply. Because the UAV task assignment results directly determine execution efficiency and results, the UAV task assignment problem has become a research hotspot in recent years.
The application of UAV technology for forest fire reconnaissance is a promising approach. However, a key challenge lies in the UAV task assignment problem, which requires the efficient and effective allocation of reconnaissance tasks to each UAV. This problem is not only characterized by large scale and high complexity but also by its demand for rapid and reliable solutions. In the event of sudden forest fires, the timely allocation of tasks to each UAV can significantly reduce the overall execution time of the reconnaissance mission and minimize the losses caused by the fire. At present, the main methods include centralized task assignment methods and decentralized task assignment methods [2,3,4].
For decentralized methods, single UAVs with information transmitting abilities have their own computing centers. Compared with the centralized methods, the decentralized methods are more flexible, but they are more complex and require higher capability for each UAV. Common decentralized methods include the auction algorithm [5], artificial pheromone algorithm [6], and contract net protocol (CNP) [7,8].
For centralized methods, tasks are assigned in a unified way. Centralized methods have been widely applied in UAV task assignment for their simple structure, high efficiency and reliability. The centralized methods can be further divided into heuristic algorithms, optimization algorithms and clustering algorithms. Common heuristic algorithms include evolutionary algorithms, swarm intelligence algorithms, etc. Yao et al. [9] proposed a three-layer UAV trajectory planning model for searching for target in complex environments. GMM was used to divide a region into multiple subregions at first. The subregions were assigned to single UAVs, and the RHC algorithm was applied to plan the trajectories for each UAV. However, targets were strictly divided based on position in this model, and it could not take into account global characteristics during task assignment. Muhuri et al. [10] proposed an immigrant-based GA for optimal task allocation. The improved GA had the ability to adaptively choose the parameters of the algorithm, and the simulation results demonstrate its superiority over the standard GA. Jena et al. [11] proposed a resource allocation method based on the GA for multi-cloud computing. It was essentially a multi-objective optimization problem. Long et al. [12] proposed a two-phase planning strategy for Low Earth Orbit satellites. The strategy included clustering preprocessing and mission planning based on the GA–SA hybrid algorithm. Simulation results verified the effectiveness and superiority of the hybrid algorithm over the GA and SA. Zhang et al. [13] established a model for UAV task allocation with four optimization objectives. Simulations based on the clone selection algorithm (CSA) and GA were conducted, and the results verified the superiority of the CSA. Xu et al. [14] proposed a two-phase model for UAV crop-spraying task allocation. First, a Multi-Objective Shuffled Frog-Leaping Algorithm (MOSFLA) was applied to allocate tasks, and then the GA was applied to optimize the UAVs’ task sequence and reduce the total execution time. However, this model was relatively simple with few considerations, and it was not suitable for large-scale, complex scenarios. Kim et al. [15] developed an optimal task assignment model for UAVs in a hostile environment, and they conducted a simulation based on the improved SL-PSO algorithm. Their results verified the reliability of the model and the algorithm. Manathara et al. [16] proposed decentralized sub-optimal and decentralized optimal coalition algorithms for the requirement of computationally cheap solutions. A simulation was conducted, and the results show that the solution provided by the proposed algorithms was close to the global optimal solution and that far less computational resources were required. Chen et al. [17] proposed an improved ant colony algorithm (ACA) with a communication mechanism due to the underutilization of the standard ACA. Mobile robot path planning simulations were conducted, and the results verified the advantages of the improved ACA. Yan et al. [18] proposed a UAV task planning optimization strategy based on Gaussian disturbance ant colony optimization. In recent years, the fireworks algorithm (FWA) has also been widely applied for multi-objective optimization [19,20,21,22]. Mnif et al. [23] used a multi-objective fireworks algorithm to solve the Pareto-optimal solutions of the optimal path planning problem in complex traffic systems and then selected a compromise solution from them. Ali et al. [24] established a mathematical model for capacity planning in 5G networks and proposed a discrete fireworks algorithm to solve it. Typical optimization methods such as the tabu search algorithm [25,26], satisfactory decision-making methods [27], exhaustive search, integer programming [28], constraint programming [29] and graph theory method [30] can also be applied for the task planning problem. However, because these are not the focus of this study, they will not be elaborated on here.
Based on a review of the literature, it is evident that centralized solving models with heuristic algorithms are commonly used for UAV mission planning problems. However, these models are often complex and require significant computing resources, which makes them unsuitable for solving task assignment problems in complex scenarios. Even when utilizing a model with lower computational complexity to assign forest fire reconnaissance tasks, the utilization of computing resources remains low, resulting in lengthy solution times. Furthermore, traditional heuristic algorithms encounter challenges in effectively addressing modern, large-scale UAV task planning problems, both in terms of solution speed and efficacy. Despite efforts by scholars to improve heuristic algorithms, it remains challenging to strike a balance between solution speed and results for large-scale problems. Although multi-step solving models and clustering algorithms as data preprocessing methods can reduce the computational workload, most research only uses clustering algorithms to divide tasks simply based on location, resulting in suboptimal solution results and difficulty in balancing the overall situation. Therefore, it is necessary to develop a large-scale UAV task assignment method that can meet the requirements of solution speed and optimization performance.
In this paper, a two-phase UAV task assignment model is proposed for the requirement of forest fire reconnaissance. This model first digitizes the forest fire based on the data obtained by sensors carried by satellites, and then, an EM algorithm based on the GMM is applied to get the initial position of each UAV. With the digital fire model and the initial position of each UAV, a UAV task assignment model is established based on the MKP. The model greatly simplifies model complexity while avoiding the problem of strict local partitioning based on location, as is the case with simple k-means algorithms. The GA is commonly used for solving the MKP, but they have slow convergence speed, high computational complexity and a tendency to get stuck in local optimal solutions. This makes it challenging to solve large-scale knapsack problems efficiently. To improve the solution speed of the standard GA, an improved GA based on the FWA is proposed for solving the MKP. The hybrid algorithm improves the mutation and crossover operators to possess the ability of adaptive adjustment of offspring quantity and mutation probability. By improving both small-scale directional search and large-scale extensive optimization, the algorithm improves the utilization of computational resources and enhances optimization, thereby improving speed and allocation effects when solving large-scale knapsack problems. Finally, based on the established model, simulation experiments were conducted under the background of a forest fire in Liangshan, Sichuan Province in 2020. The simulation results show that the model can solve the fire reconnaissance task allocation problem quickly and effectively. In addition, the hybrid algorithm demonstrated faster solution speed and shorter running time compared with the standard GA and other improved algorithms. The contributions of this study are as follows:
- (1)
- This paper presents a novel task allocation model that addresses the challenges of complex and large-scale reconnaissance tasks in forest fire monitoring using UAVs. First, this study introduces the EM algorithm of GMM to determine the center of the task points cluster and sets it as the initial position of each UAV instead of using a clustering algorithm to simply assign tasks based on location. Then, based on the initial position of each UAV, an MKP model is innovatively used to solve the task allocation problem. Each UAV is treated as a knapsack, and the tasks are treated as valuable items. This cleverly achieves the assignment of tasks to the UAVs.
- (2)
- Inspired by the number and radius of sparks in the fireworks algorithm, improvements have been made to the mutation and crossover operators in GA, enabling dynamic adjustment of mutation probability and the number of mutated offspring. The results of simulation experiments show that this algorithm has a fast convergence rate and good optimization performance, achieving a twofold improvement in solution speed and optimization effect.
- (3)
- Based on the forest fire in Liangshan, Sichuan Province, a simulation experiment was conducted to assign missions to UAVs based on the satellite’s remote sensing information. The experiment validated the feasibility and superiority of the model and algorithm, and the experimental method and results provide a reference for future UAV reconnaissance mission assignment in disaster areas.
The rest of this study is organized as follows. Section 2 introduces the UAV forest fire reconnaissance task model used in this paper. The FW–GA hybrid algorithm and clustering algorithm used in this study are presented in Section 3. The details of the simulation study carried out are in Section 4. Section 5 concludes this work.
2. Description of the Model for Forest Fire Reconnaissance
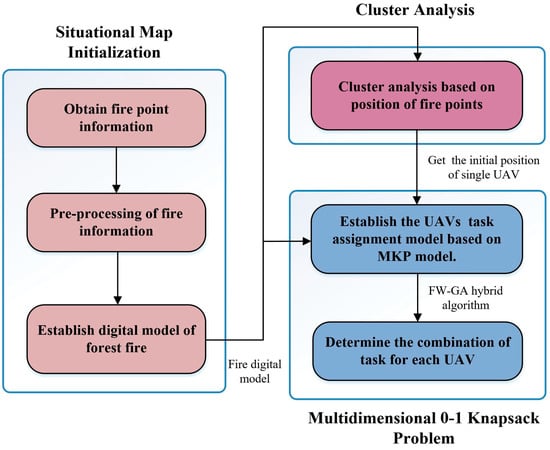
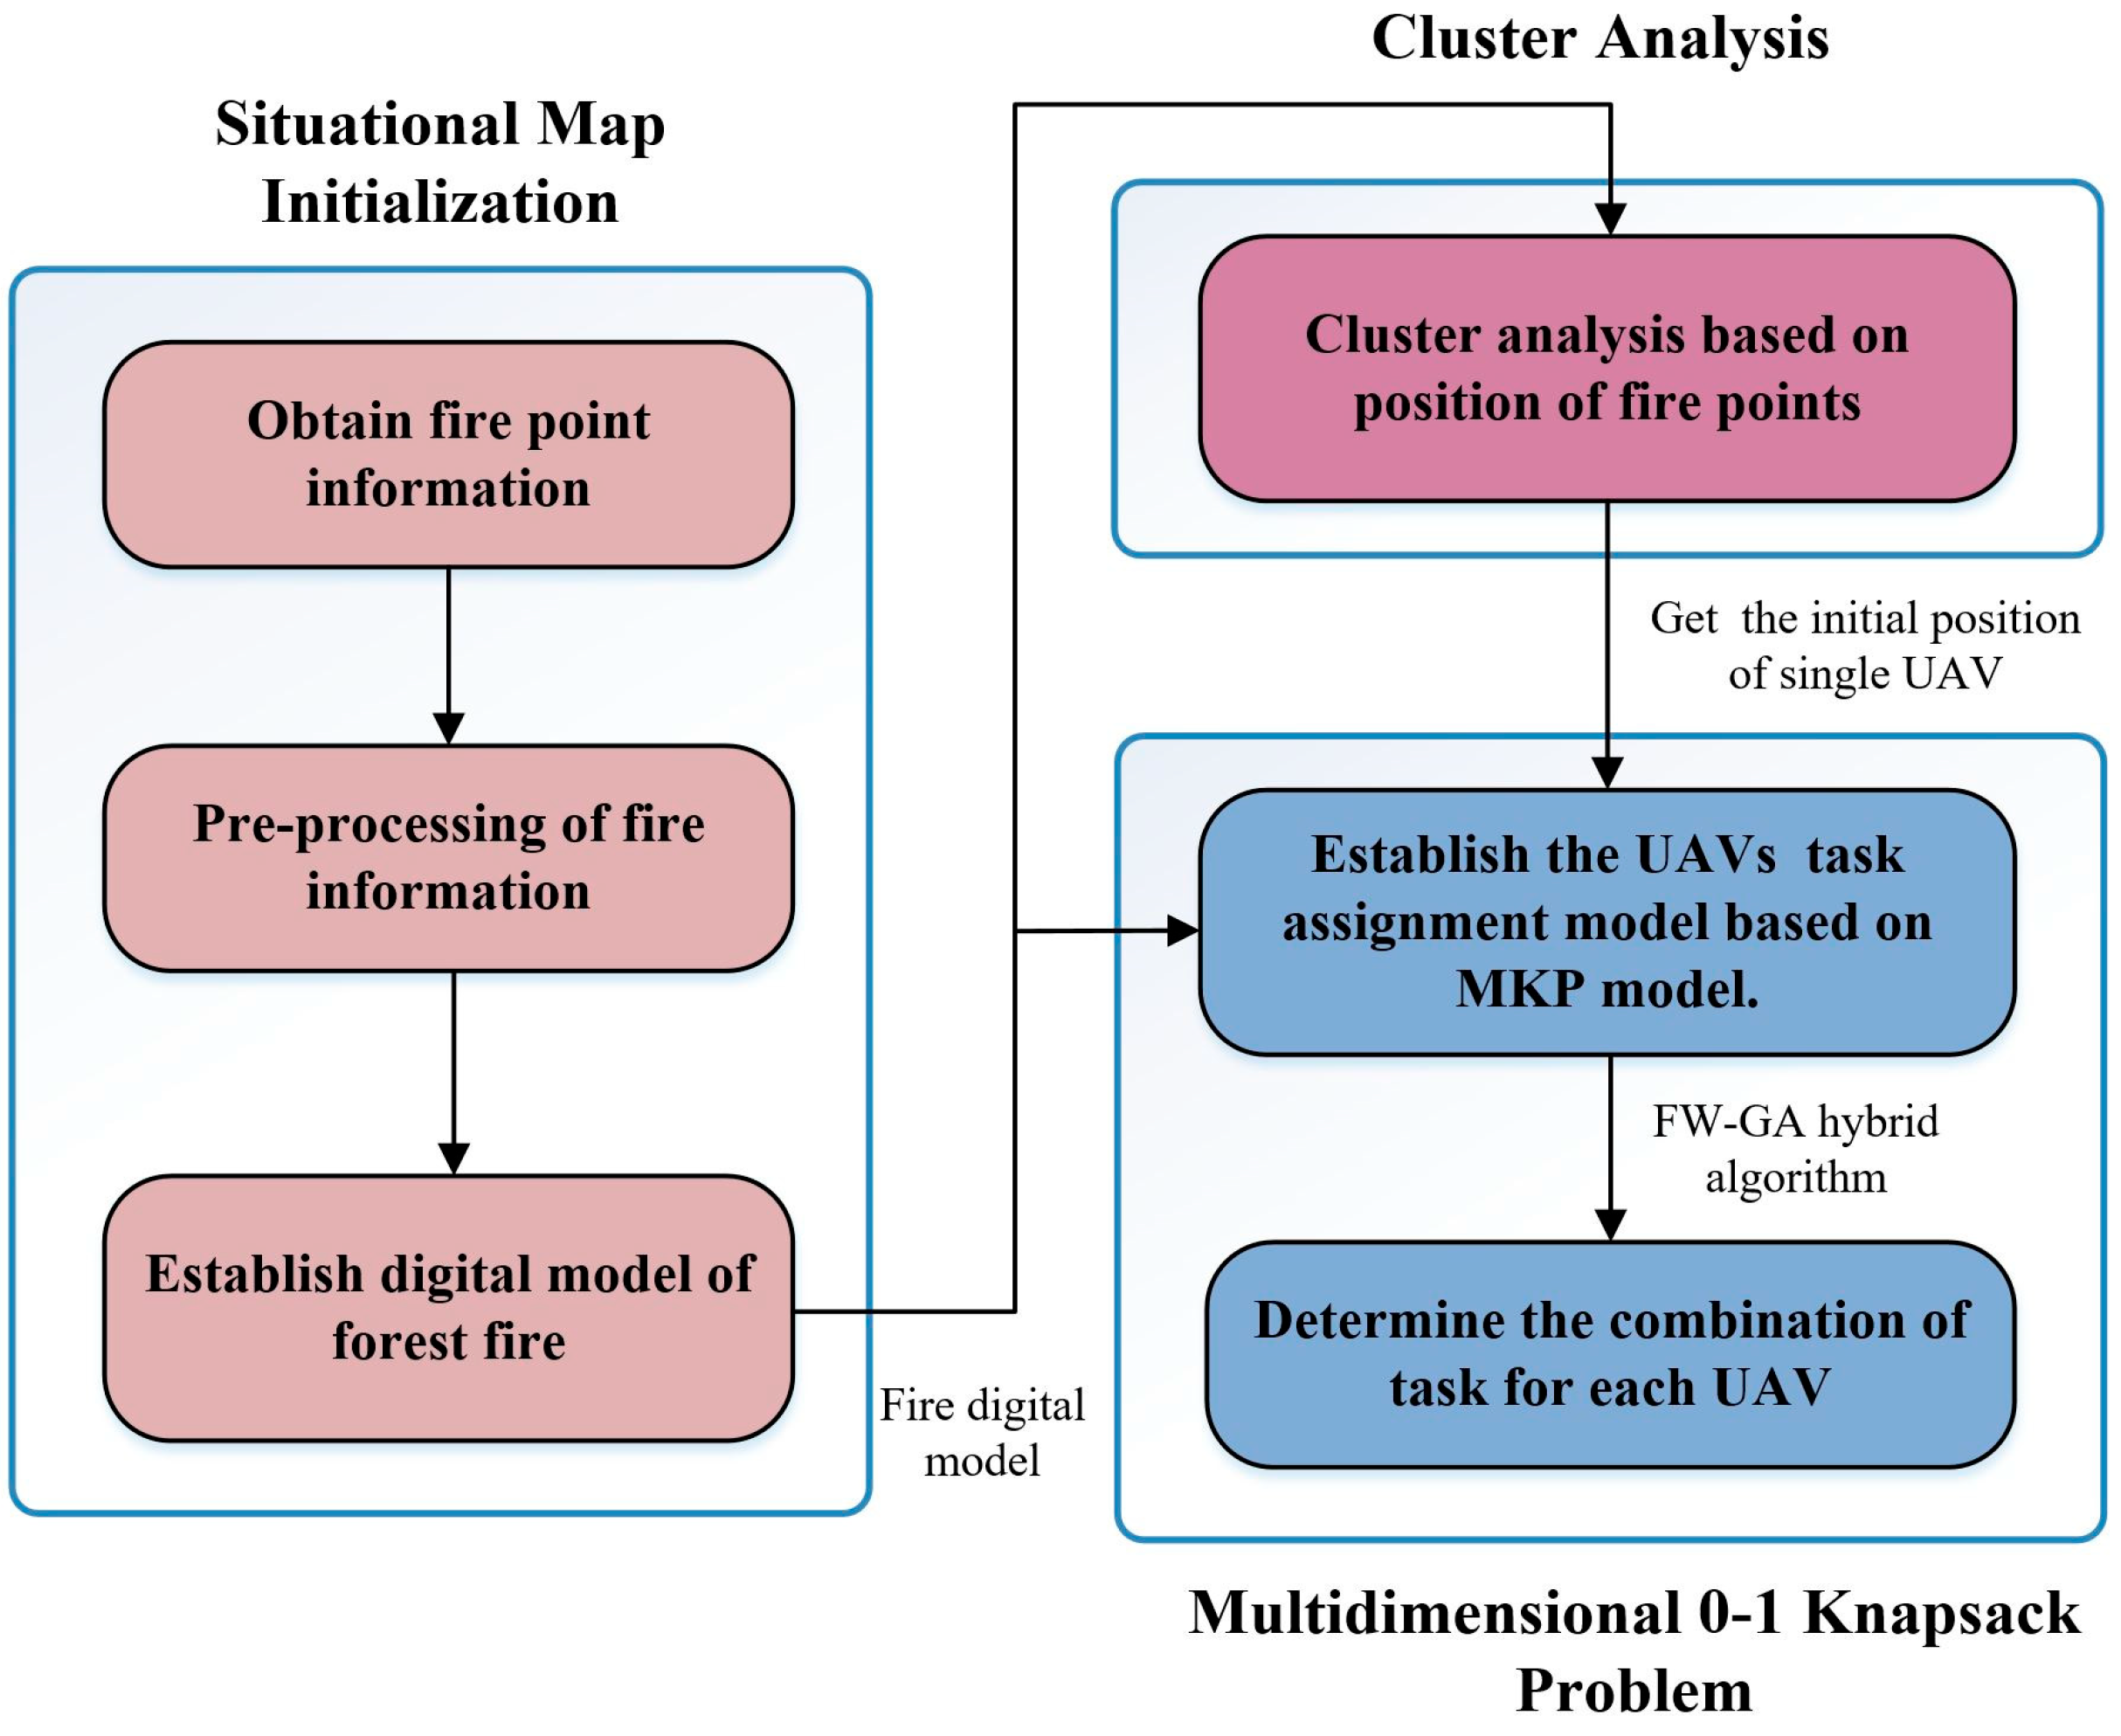
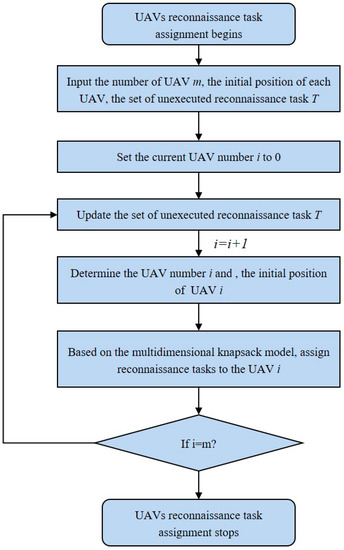
A UAV fire reconnaissance task assignment model is necessary for the efficient reconnaissance of forest fires. First, the forest fire is digitally modeled based on the fire points’ information obtained from the satellite-borne sensors. Then, the GMM is utilized to approximate the fire points distribution map, and the two-dimensional expected coordinates of each Gaussian distribution are set as the initial positions of each UAV. Finally, the UAVs are considered as knapsacks, and the fire points are considered as items. The MKP model is adopted to solve the UAV reconnaissance task assignment problem. The tasks for each UAV are thereby determined, as well as the fire points in each “knapsack”. The detailed process of the UAV reconnaissance task assignment model is shown in Figure 1.
Figure 1.
Flowchart of the model for forest fire reconnaissance.
2.1. The First Step: Initialization of the Situation Map
This study took the forest fire that occurred in Muli County, Liangshan Prefecture, Sichuan Province on 30 March 2020 as the background. The fire information was sensed using the Visible Infrared Imaging Radiometer (VIIRS) carried on the NOAA-20 satellite as well as the Moderate-resolution Imaging Spectroradiometer (MODIS) carried on the Terra and Aqua satellites. In addition, the sensed information can be obtained from the FIRMS website (https://firms.modaps.eosdis.nasa.gov/map/#t:adv;m:advanced;d:2020-03-30;@101.5,27.9,12z (accessed on 8 February 2022)) of NASA.
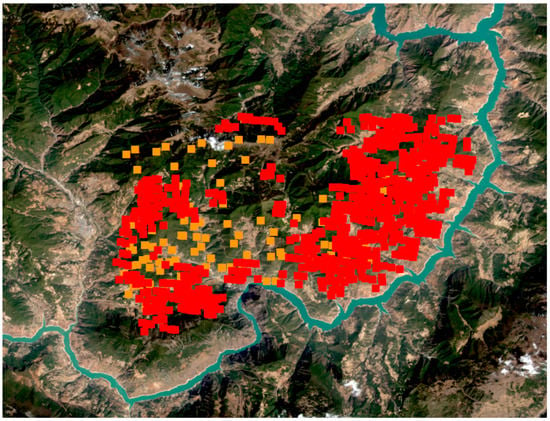
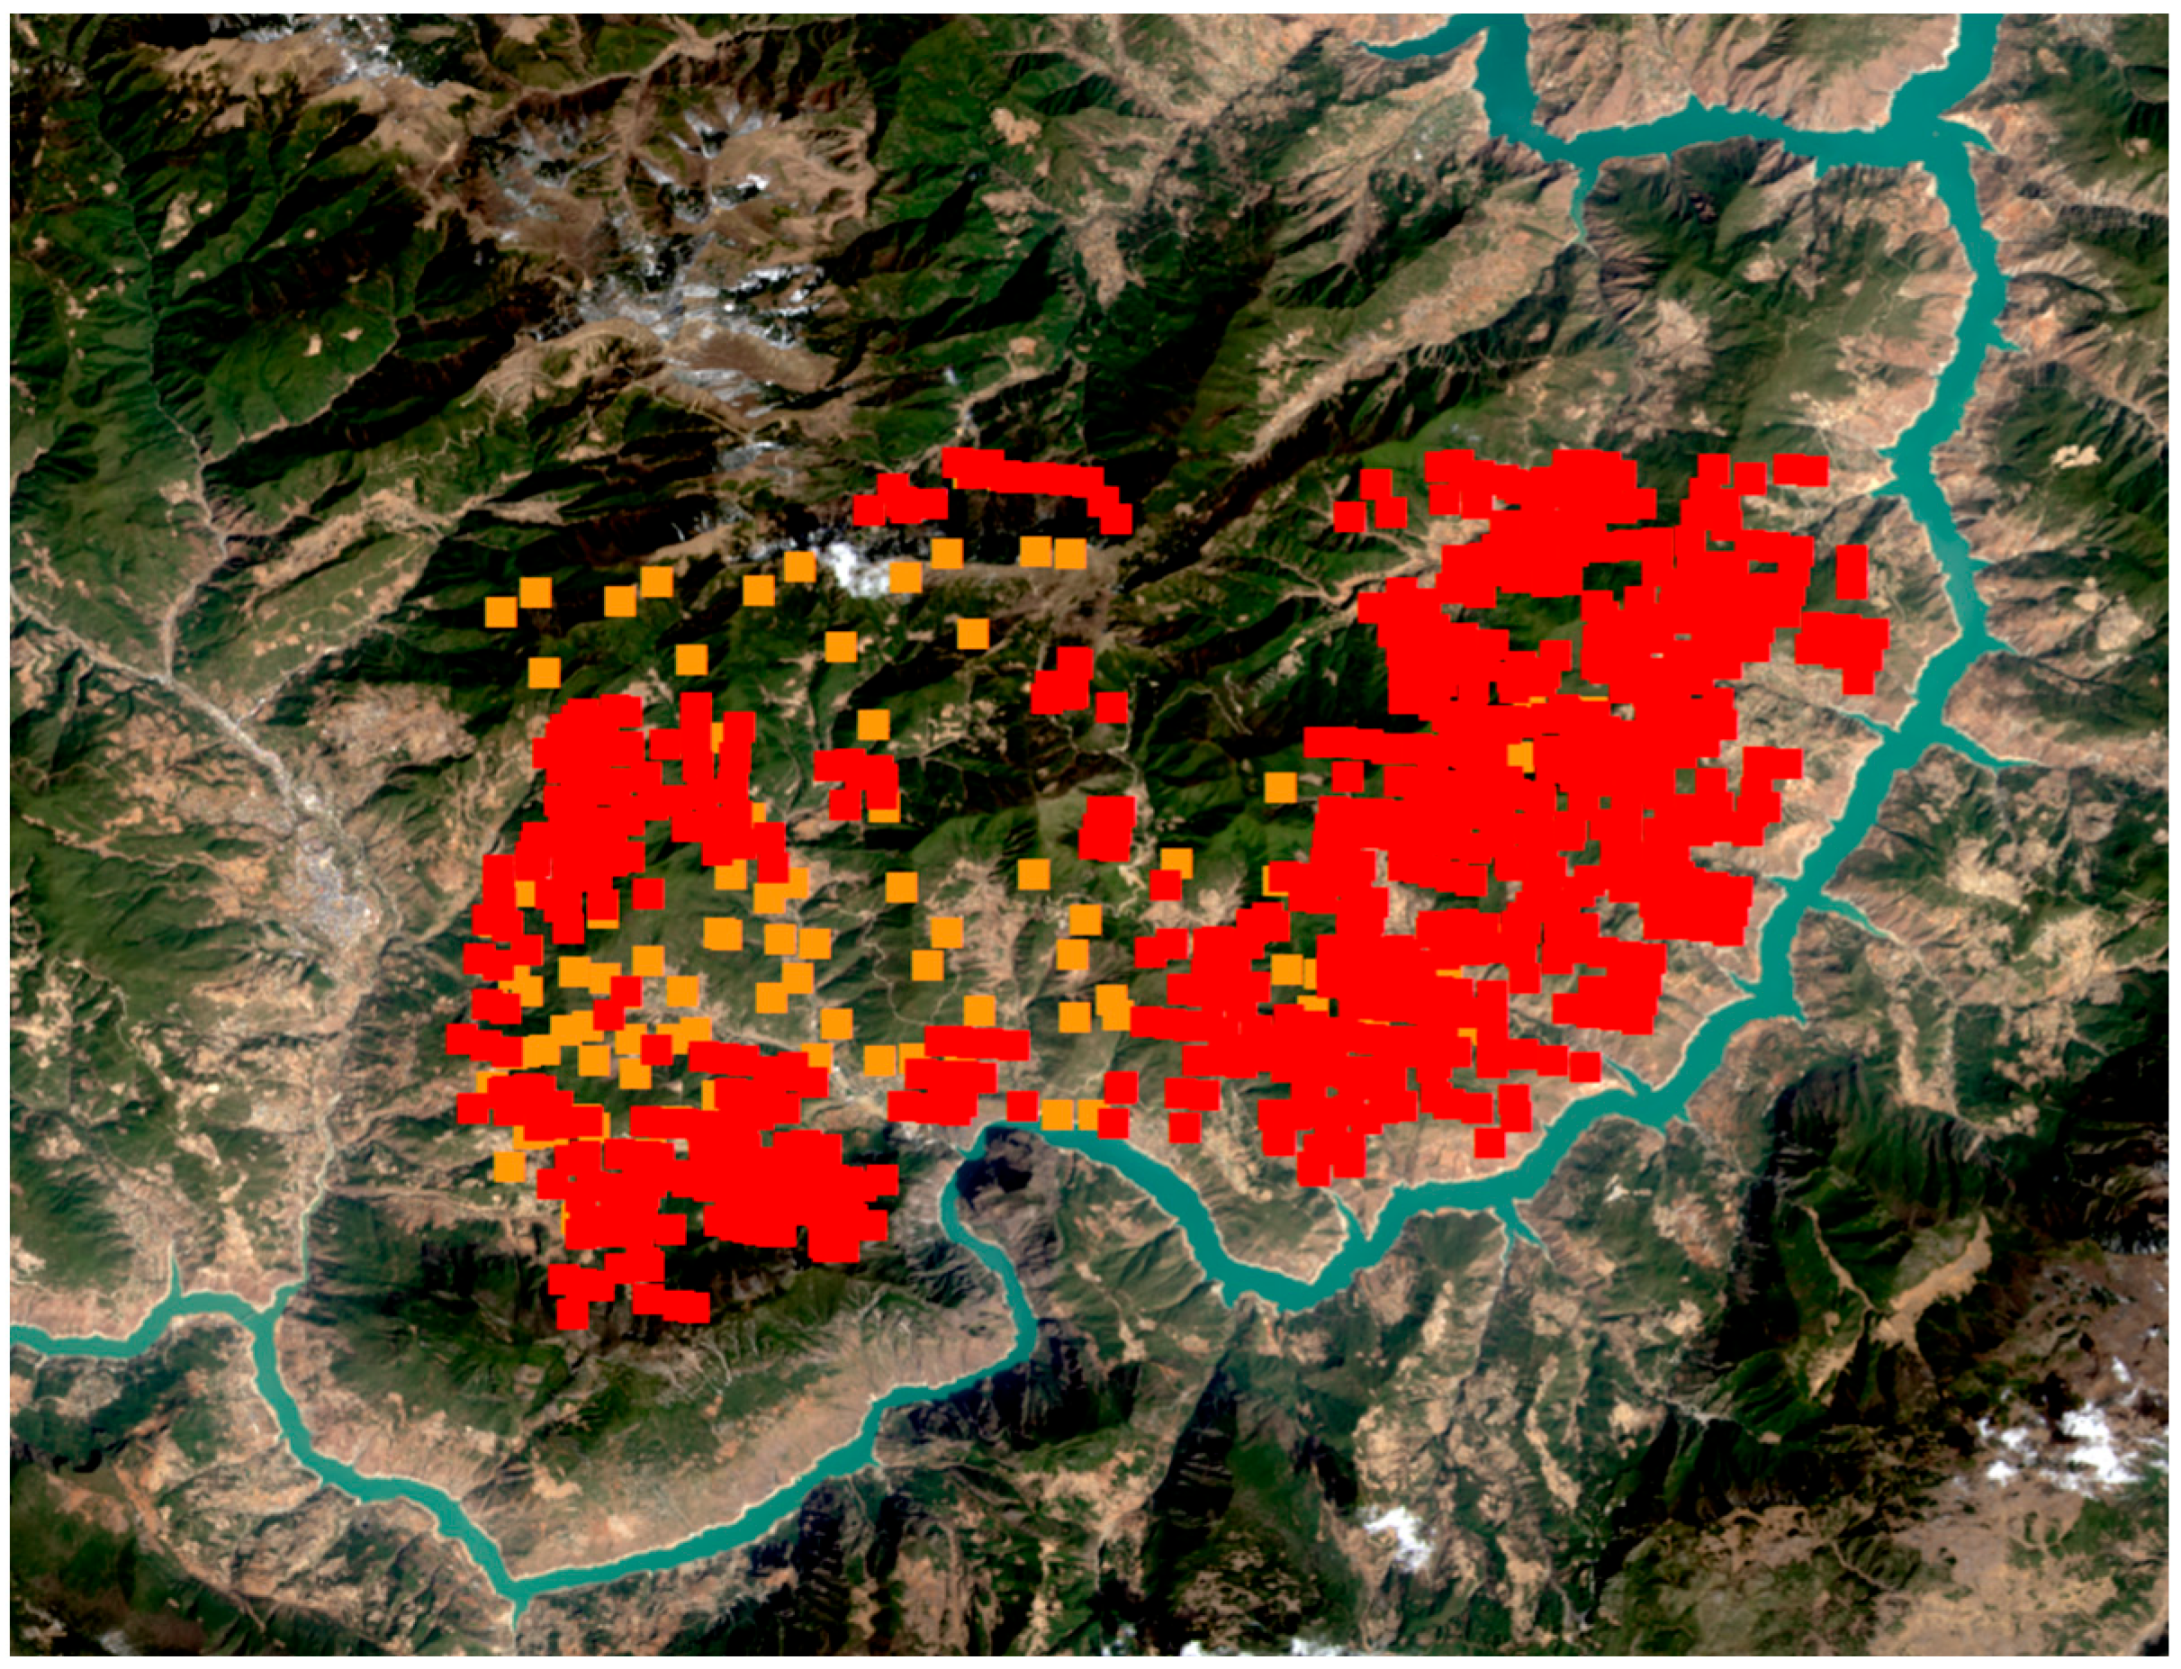
Using FIRMS, the fire information at Muli County, Liangshan Prefecture, Sichuan Province (roughly 27.9° N, 101.3° E) on 30 March 2020 was obtained. Figure 2 was obtained based on the data from FIRMS; the red square points represent the fire situation sensed by the VIIRS, and the orange square points represent the fire situation sensed by the MODIS.
Figure 2.
Fire point distribution map. (The red square points: the fire situation sensed by the VIIRS. The orange square points: the fire situation sensed by the MODIS).
With the SHP format fire data file obtained from the website on 30 March, the information of 886 fire points obtained by the VIIRS sensor and MODIS sensor on 30 March was received, including fire point latitude and longitude coordinates, fire point shooting date, fire point FRP (Fire Radiation Power, unit MW), shooting sensor, etc. Based on the ArcGIS 10.4 software, the latitude and longitude coordinates were transformed into 2D coordinates under the WGS84 coordinate system (Beijing 54), and the FRP values were bound to each fire point. Because the origin of the Beijing 54 coordinate system is Pulkovo of the Soviet Union, the 2D coordinates need to be shifted without changing their relative positions. Thus, the minimum values of the x and y coordinates, and , were selected as the new origin, and a digital model was established.
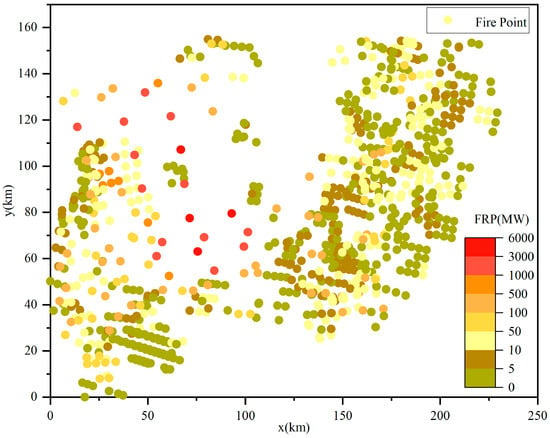
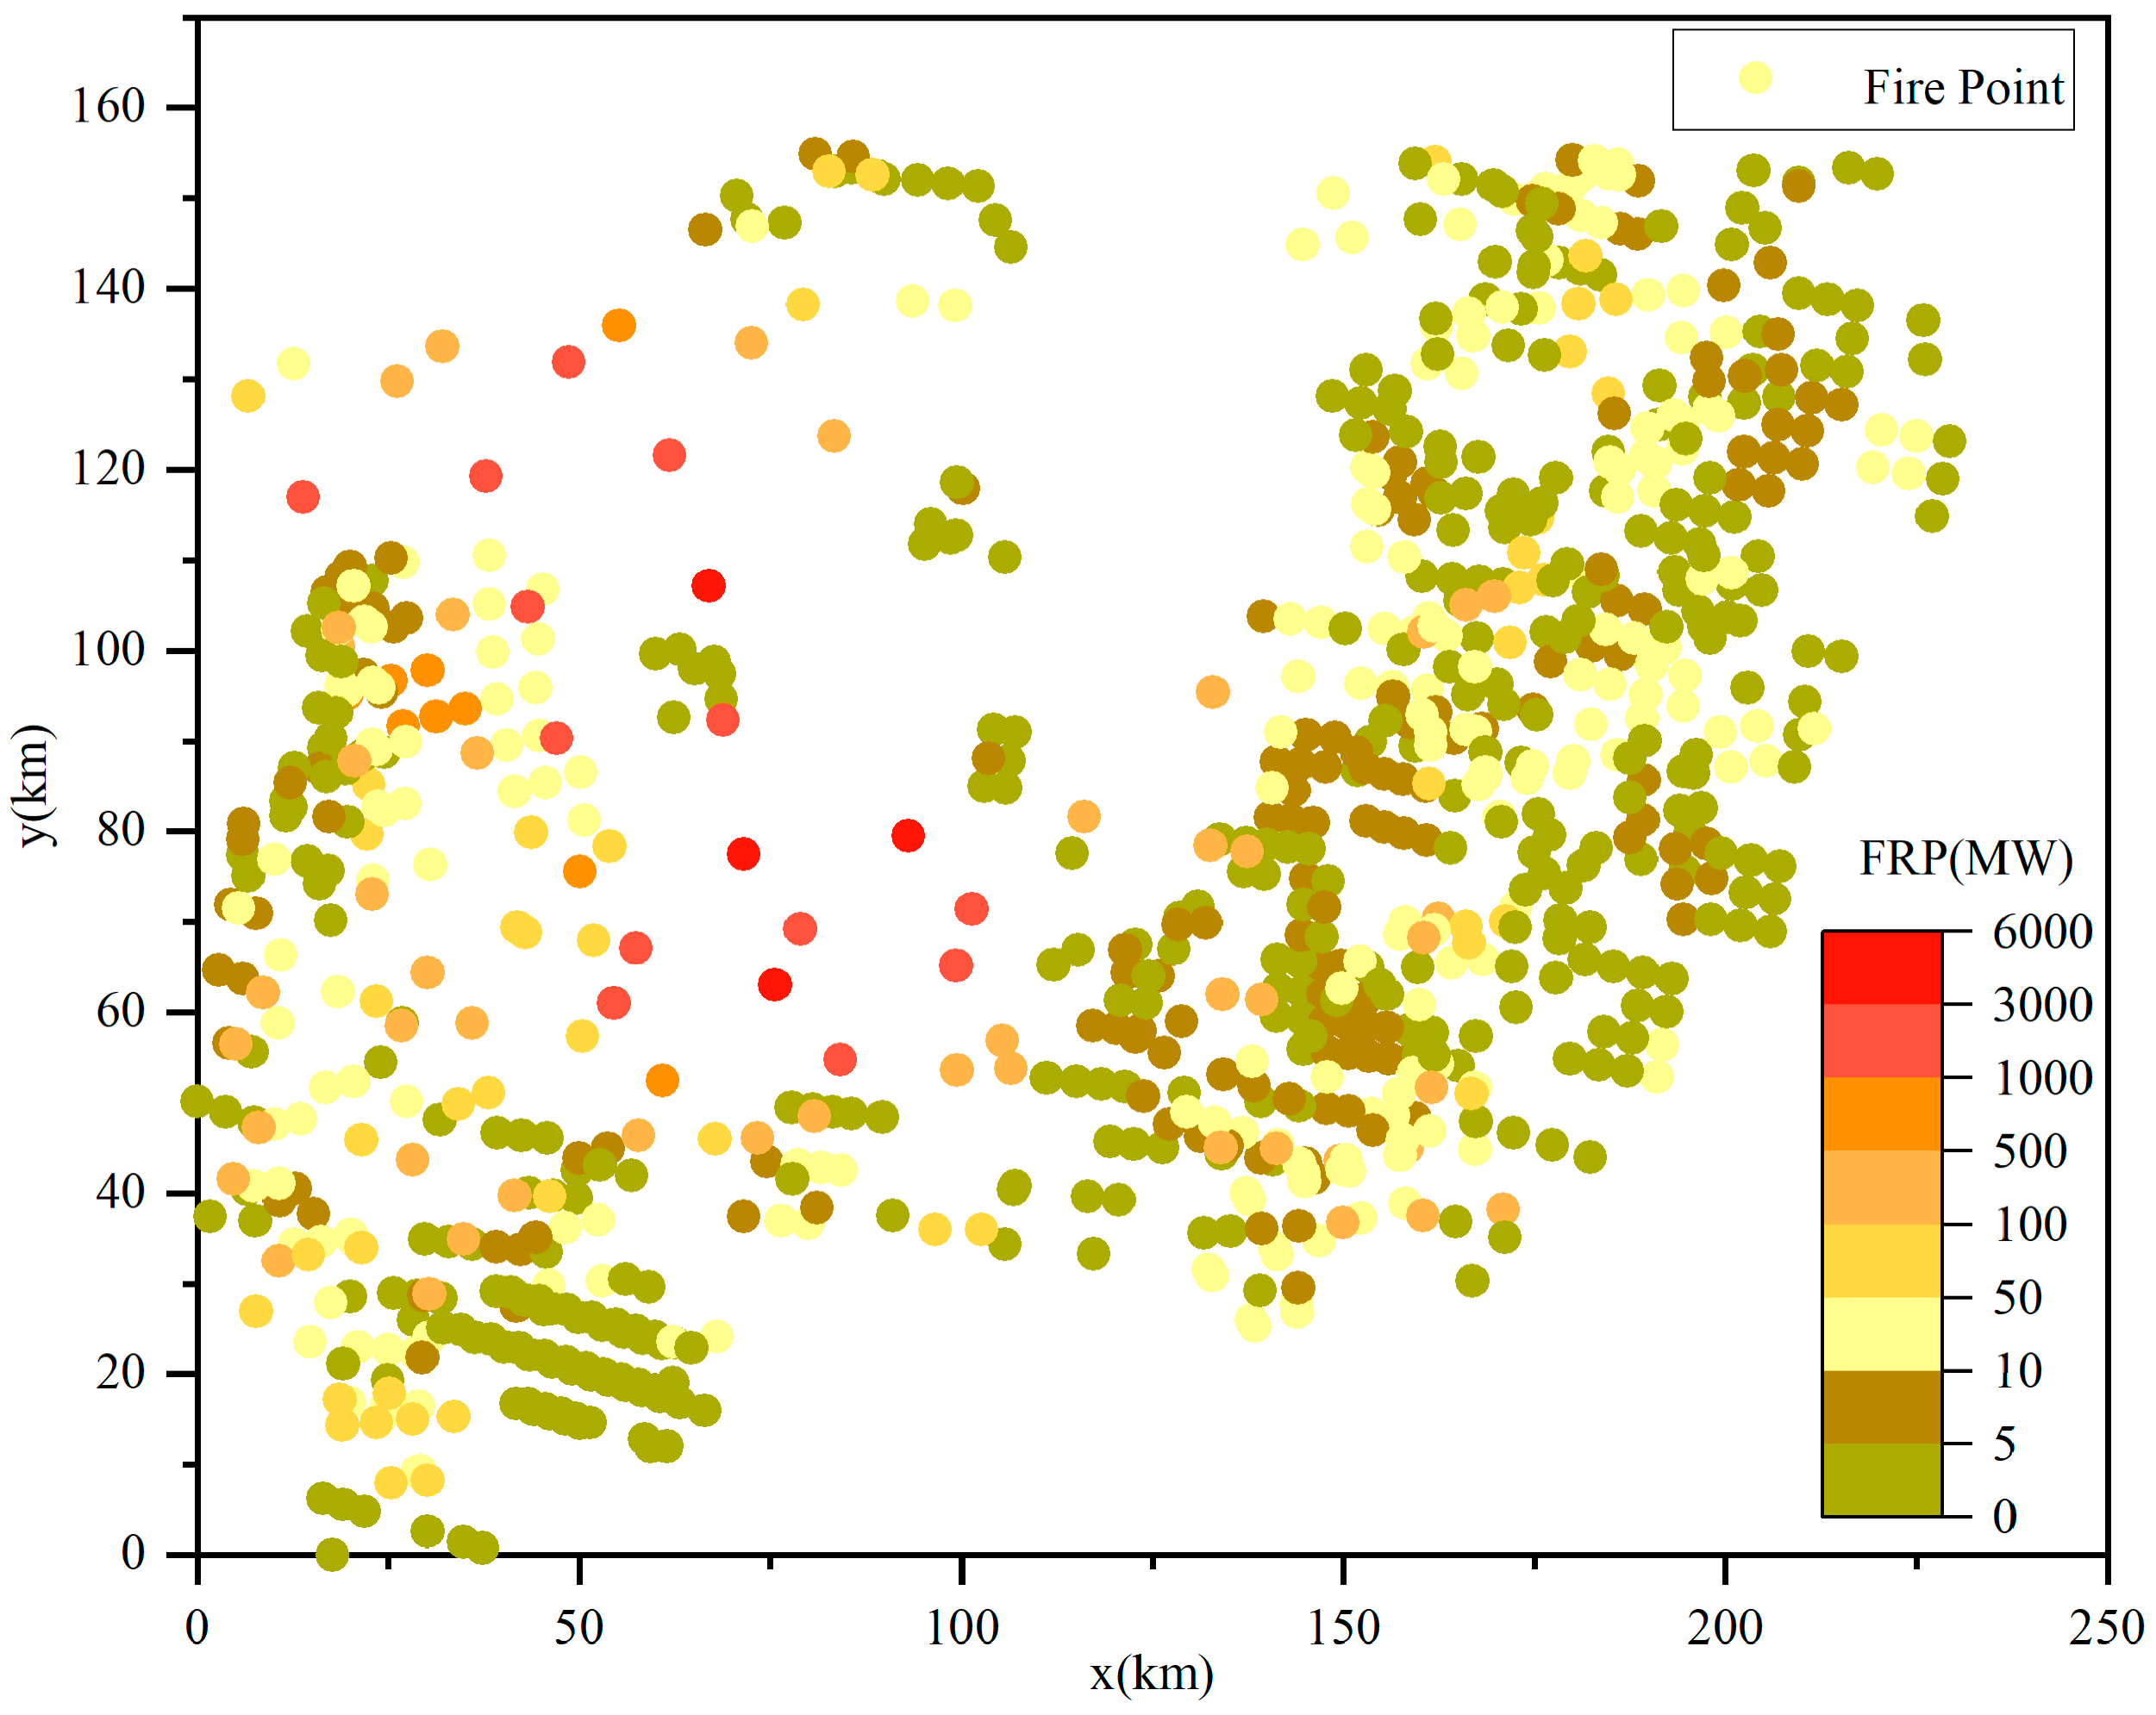
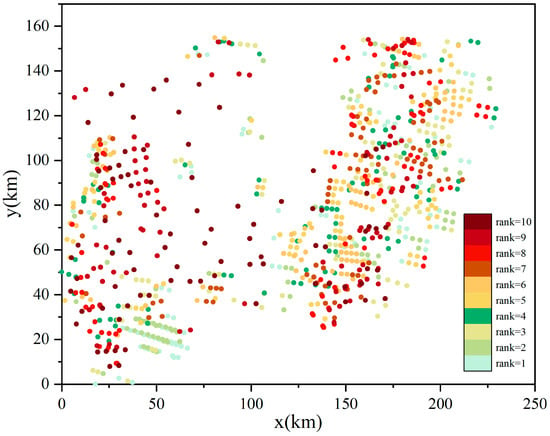
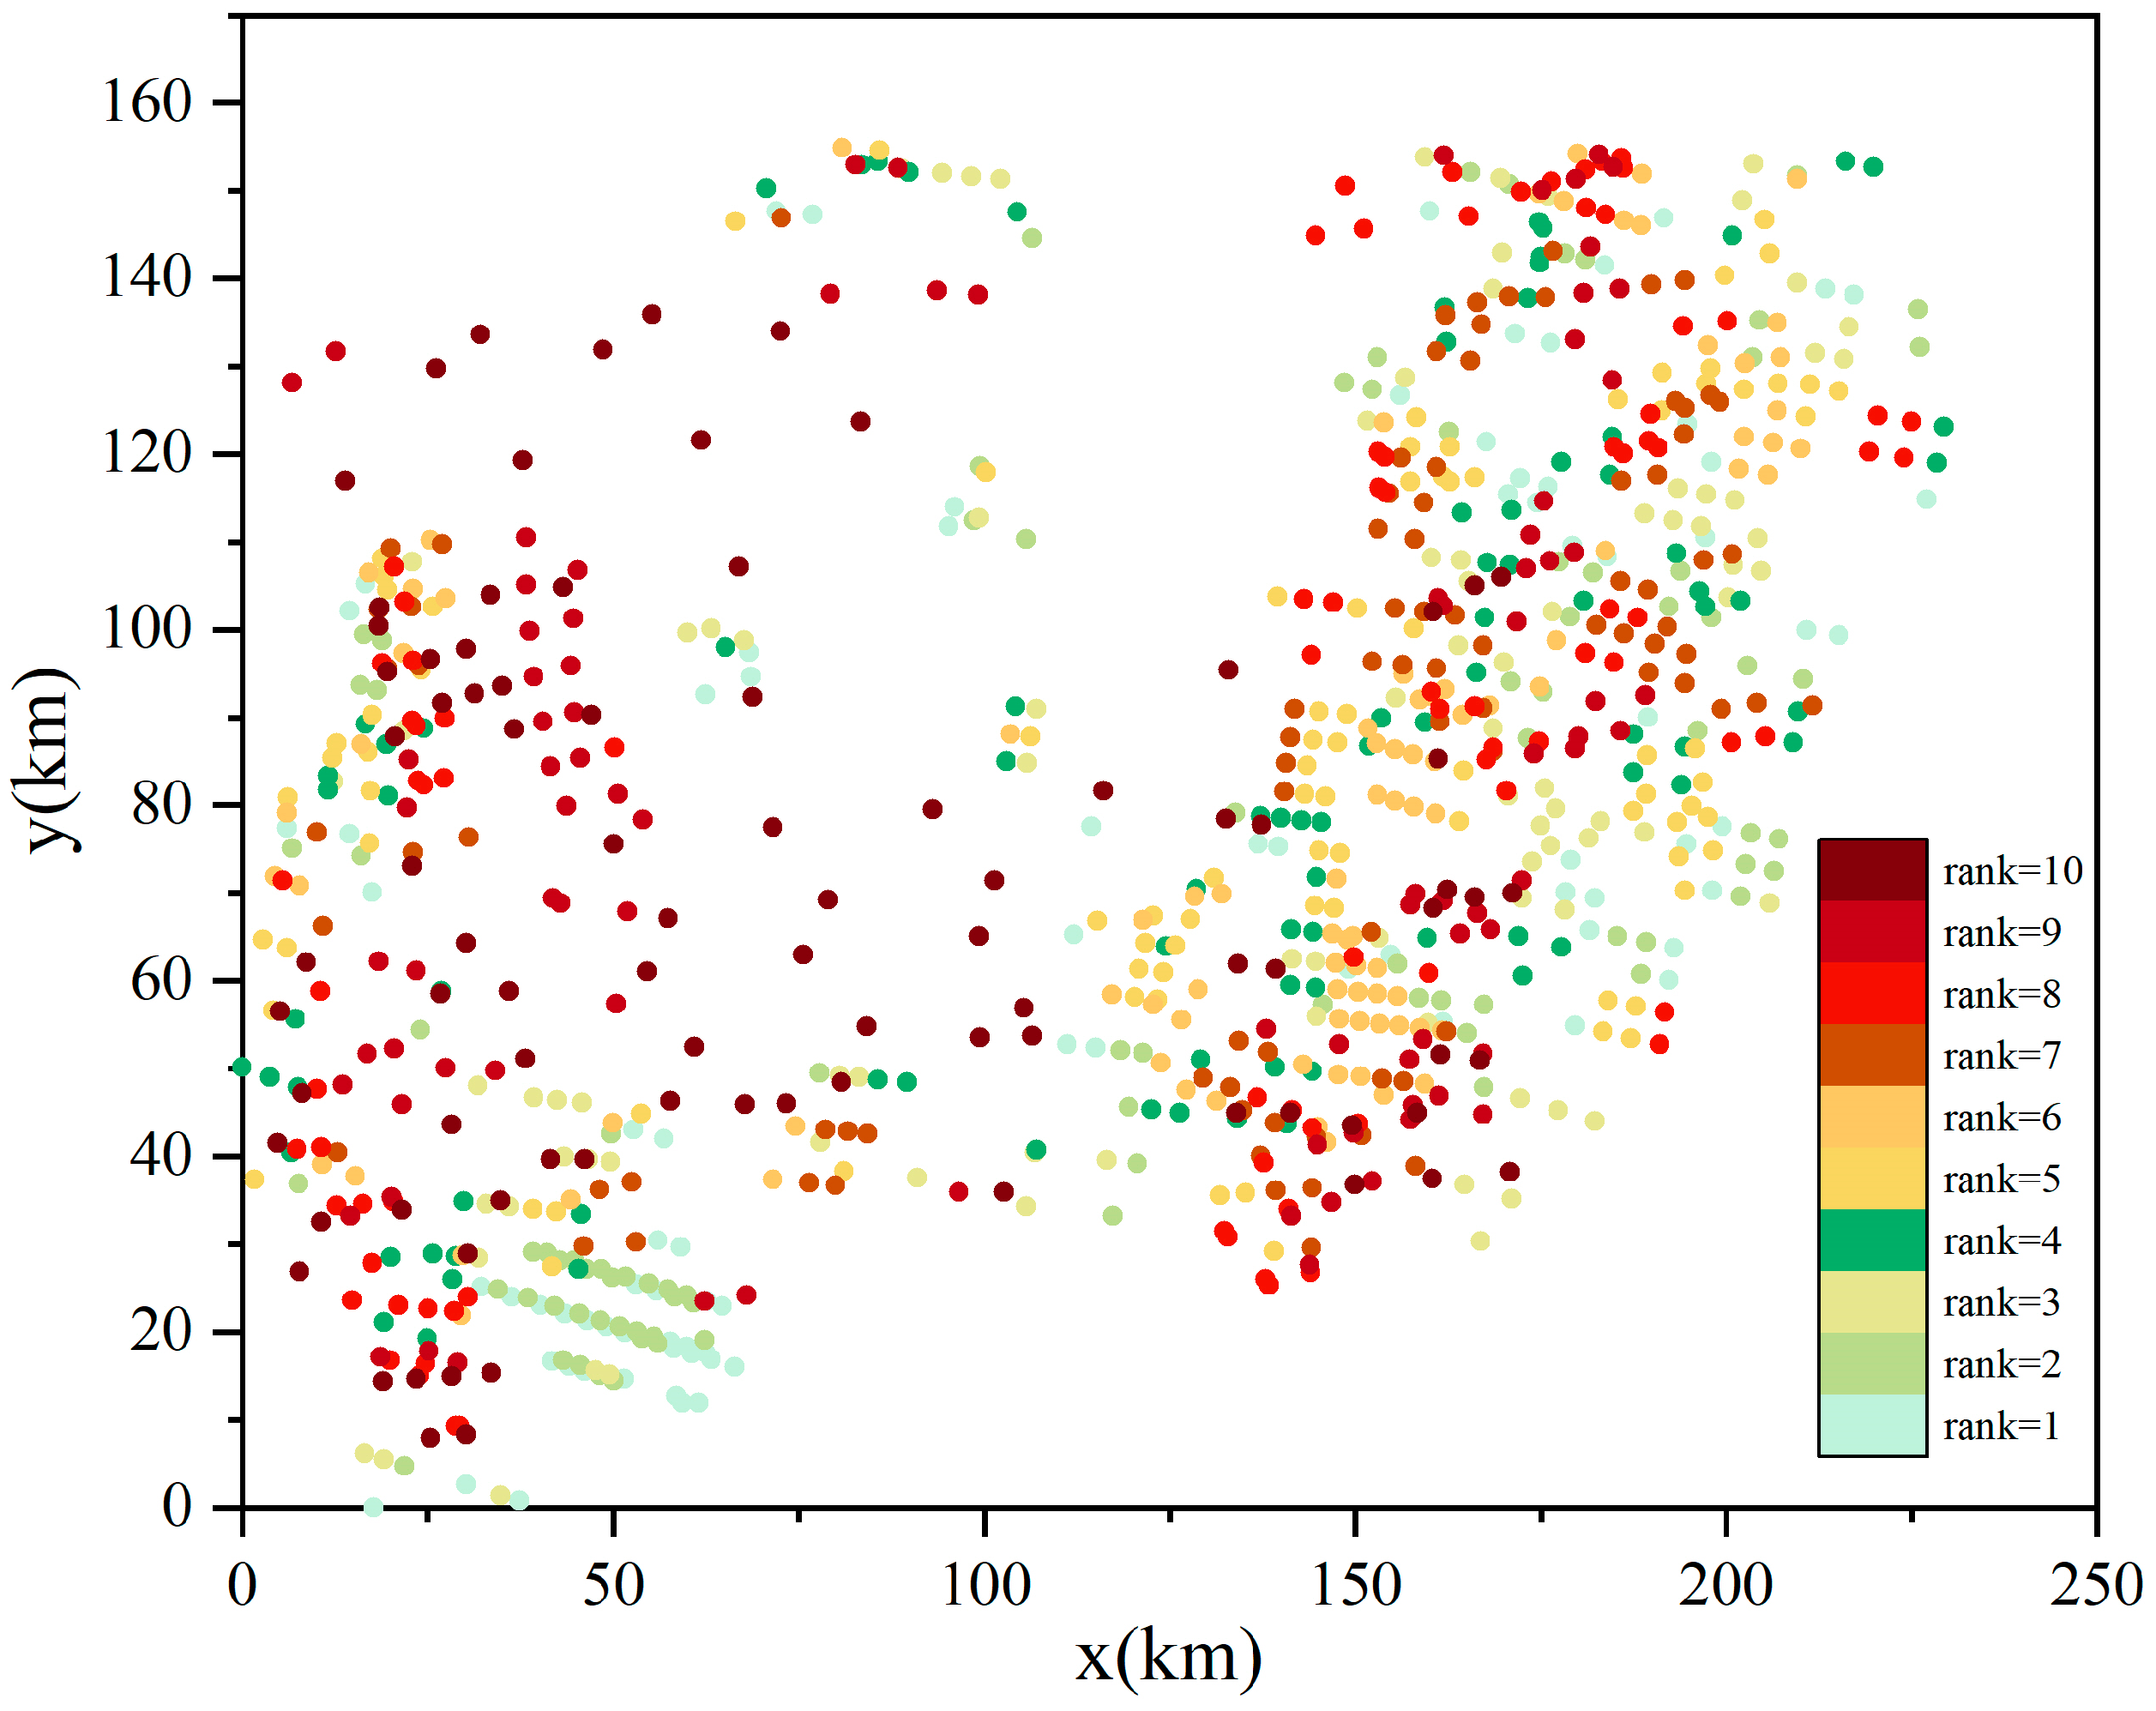
There are 886 fire points in Figure 3. Where the FRP values of different fire points varies, different colors are used to represent the radiation power of different fire points. It can be inferred that points with higher FRP values have a higher priority for reconnaissance. However, it can also be seen from the digital model that there are very few fire points with FRP values above 500. If the FRP value is directly used as the priority of each fire point, the optimal solution based on the task assignment model will be dominated by a few points with high FRP values. Therefore, a system for ranking is necessary. Here, the priority of fire points is divided into ten levels. The top 10% of fire points based on FRP are assigned a priority rank of 10, the next 10% are assigned a priority rank of 9, and so on. The fire points’ rank distribution is shown in Figure 4.
Figure 3.
Digital model of the forest fire field.
Figure 4.
Fire points rank distribution.
The mathematical expression of fire point information set is shown as follows:
where is the x-direction coordinate information of the fire point , is the y-direction coordinate information of the fire point and is the priority rank of the fire point .
2.2. Clustering Analysis
The fire points are classified based on the fire points’ location information with the clustering algorithm. The fire points that are close to each other are classified into the same “cluster” to obtain fire points clusters . In addition, the number of clusters is equal to the UAV number :
where is the fire points set of the cluster and is the index array of the fire points in cluster . According to the divided cluster, the center points of each cluster is acquired:
where is the x-coordinate of the center position of fire point cluster and is the y-coordinate of the center position of the fire point cluster . Finally, the center positions are set as the initial position of each UAV.
2.3. Multidimensional 0-1 Knapsack Problem
After obtaining the initial position of each UAV, the UAV task assignment model is considered as a multidimensional 0-1 knapsack problem.
Figure 5 depicts the process of task allocation for the UAVs. The task assignment problem for each UAV is solved sequentially, thereby facilitating the solution of the entire UAV task allocation problem. After obtaining the initial positions of each UAV, the task allocation problem for individual UAVs in the group can be modeled as a multidimensional 0-1 knapsack problem. In this problem, each UAV is treated as a multi-constraint knapsack with multiple dimensions of “capacity” restrictions, such as flight range and storage space for reconnaissance information. Each fire point is treated as an item with different values and volumes in the knapsack, where the value of each item represents the rank value of the fire point, and the volume occupied by each item represents the battery consumption and storage space required for UAV reconnaissance of the fire point. The objective is to find the combination of fire points with the highest rank value that satisfies the constraints of UAV flight range and storage capacity.
Figure 5.
Flowchart for solving the UAV task assignment problem.
The constraints of the multi 0-1 knapsack problem are as follows:
- Modern UAVs are usually powered by lithium batteries. They generally carry heavy equipment for reconnaissance missions, and that greatly limits their flight range. Therefore, the sum of the distances between the fire points assigned to a single UAV and the UAV itself must be limited to satisfy the endurance limit of the UAV.
- To avoid repeated reconnaissance, each new task point must be a hitherto unreconnoitered point.
- Higher priority points require more detailed reconnaissance for the effectiveness of missions. Therefore, careful reconnaissance is required for higher priority points, and the reconnaissance information generated will consume more storage space. Thus, the storage space of a single UAV is also an important limitation.
- To shorten the execution time of each UAV’s mission as well as to facilitate the subsequent path planning for each UAV, it is necessary to limit the total number of fire points assigned to each UAV.
The mathematical model of the constraints was established as follows:
- Range constraints for UAV reconnaissance.
In most studies, the task region is divided into multiple subregions, and then tasks are assigned within each subregion, which leads to the problem that each UAV only performs reconnaissance missions within a certain delineated area. To better balance global considerations, the range constraint of each UAV is set as the sum of the distance between the UAV and each assigned reconnaissance point. Each UAV can thereby not only perform missions in areas closer to itself, but also assist in reconnaissance of the areas closer to other UAVs where there is a larger number of missions of higher priority.
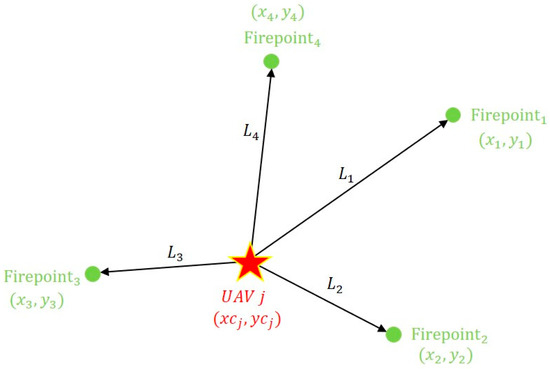
In Equation (4), is the index array of fire points assigned to UAV , , is the x-coordinate and y-coordinate of the fire point in set , , is the x-coordinate and y-coordinate of the initial position of UAV and is the range limitation. This equation represents that the sum of distances between all assigned fire points and the initial position of UAV j should be less than . As shown in Figure 6, when UAV j is assigned four reconnaissance points, this constraint can be expressed as:
Figure 6.
Diagram of range constraints.
- The fire points assigned to the UAVs should be the points that have not been detected before.
An 886-dimensional vector is defined, and if the fire point has not been detected, ; otherwise, . Therefore, if the fire point has not been reconnoitered, we can obtain:
- Storage space constraint for each UAV.
A vector is defined to represent the storage space consumed by each fire point. The higher priority of the fire points are, the greater the amount of reconnaissance information will be generated, and therefore, storage space consumption will greatly increase. Thus, the parameter is defined to be linearly corelated with the square of the priority of the fire point. is defined as follows:
where is the storage space consumption of the fire point and is a coefficient, and for the convenience of calculation, .
Therefore, the storage space constraint for each UAV can be expressed as:
where the is the storage space constraint for each UAV.
- Constraint of the number of assigned fire points for each UAV.
The mathematical expression is as follows:
where is defined in Equation (6) and the is the constraint of the number of assigned fire points for each UAV.
- Objective function.
According to the definition of the value of items in the previous context, the sum of the priority levels of all fire points assigned to each UAV is defined as the objective function of the MKP:
where is the objective function value of the UAV and and are as defined previously.
3. UAV Reconnaissance Task Allocation Strategy Based on Improved GA Combined with Cluster Analysis
Based on the model established in the previous section, an EM algorithm based on the GMM (Gaussian Mixture Model) is applied to approximate the fire points distribution. The Gaussian mixture model contains (the number of single UAVs in the group of UAVs) two-dimensional Gaussian distributions. The two-dimensional Gaussian expectation is obtained using the EM algorithm, the initial position of the UAV is set as the expectation. GA has been widely used to solve the multidimensional 0-1 knapsack since P. C. et al. [31] first proposed it in 1998. To further accelerate solution speed, an FW–GA hybrid algorithm is proposed to solve the MKP problem, and the Binary Elite Opposition-based learning mechanism [32] and greedy selection operators are also introduced into algorithm. Thus, the optimal combination of fire points for each UAV is obtained.
3.1. Initial Position Determination Using the EM Based on GMM
3.1.1. Fundamental Theory
GMM (Gaussian Mixture Model) refers to a combination of multiple Gaussian mixture models with certain weights. In theory, a GMM can fit any type of distribution. In this problem, the GMM consists of m two-dimensional normal distributions, where each two-dimensional Gaussian distribution is called a component. The mathematical expression is shown below:
where the is the weight of the Gaussian distribution k; is the mean of the Gaussian distribution k; is the variance of the Gaussian distribution k; represents the collection of coordinates of fire points, where , are as defined in Equation (1); d is the dimension of , in this case, d = 2. In addition, satisfies .
Here, is regarded as the probability of the Gaussian model k being selected. In addition, a new m-dimensional variable, , is introduced (m is defined as the number of single UAVs), where has only two values, 0 or 1:
Based on the Bayesian formula, we finally get posterior probability :
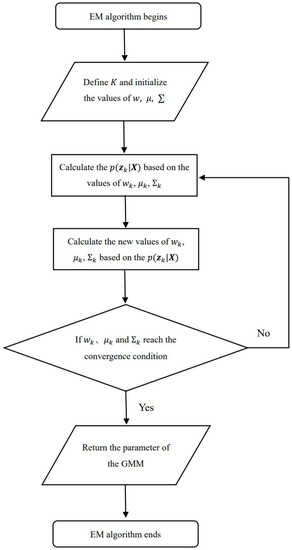
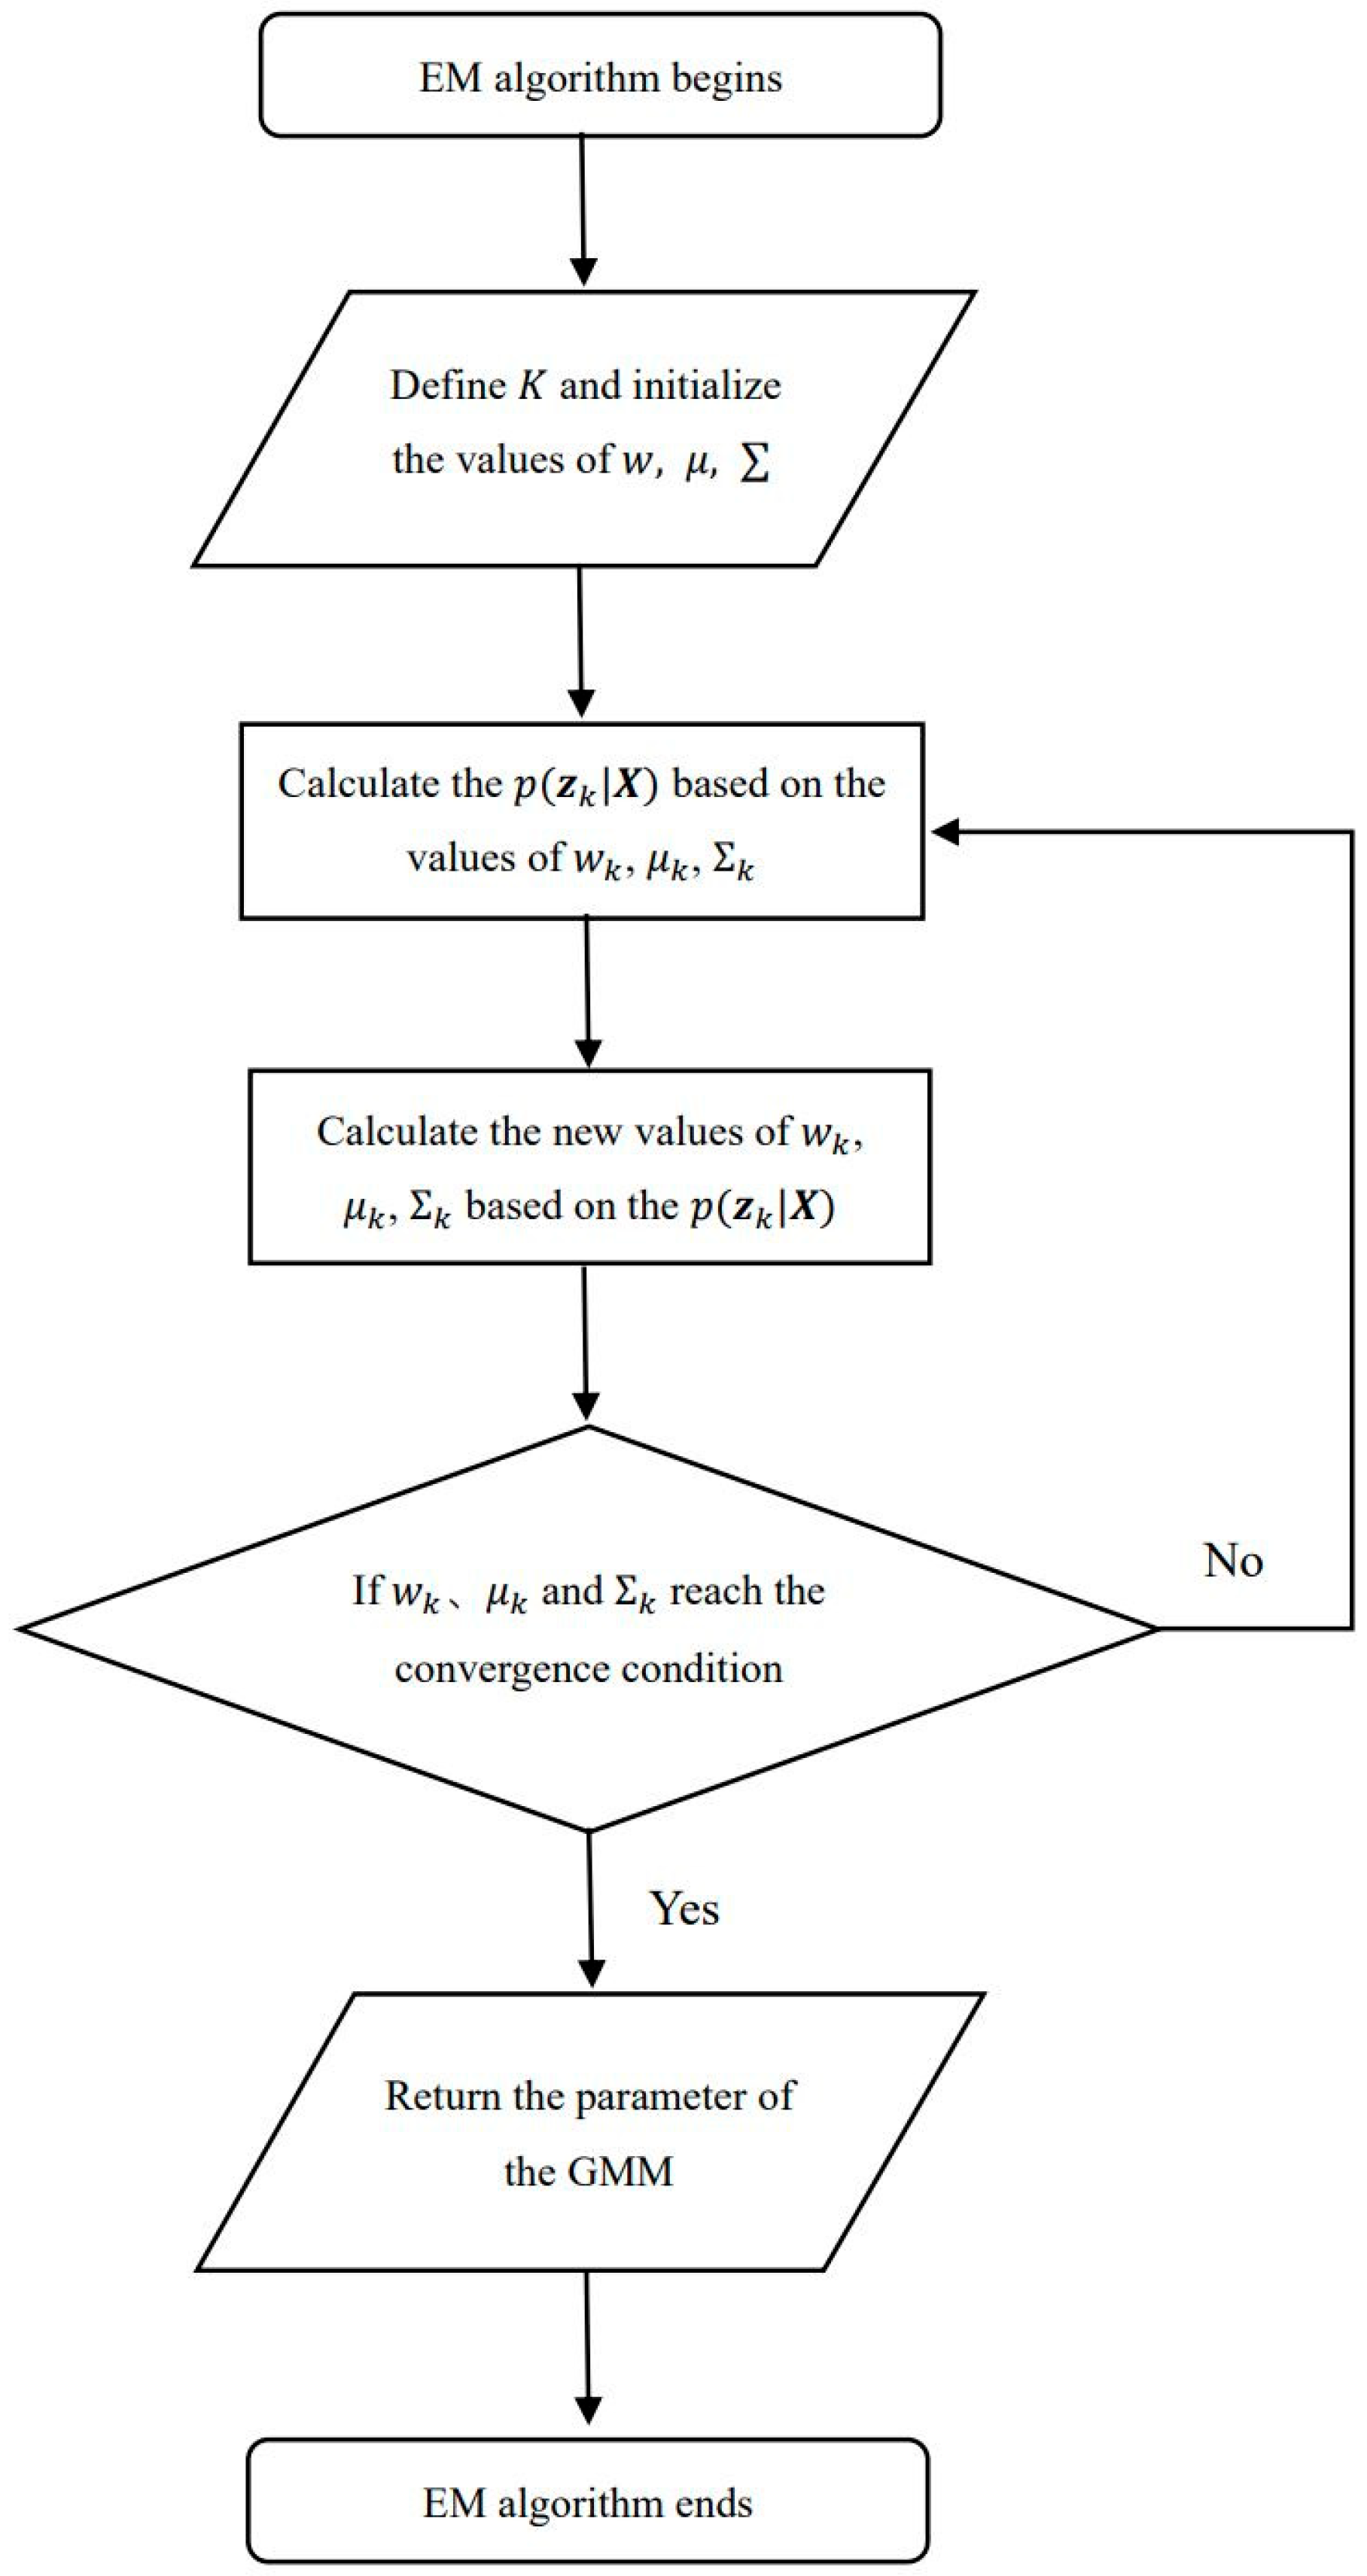
The EM algorithm is used to find the maximum likelihood estimation of each parameter by likelihood. The EM algorithm can be divided into two steps. The first step involves computing the posterior probability based on the existing parameters. The second step involves computing new parameters based on the values of the posterior probabilities. The iteration process is repeated to obtain the parameter values of the GMM. The methods for obtaining the three parameters , and are relatively straightforward and will not be elaborated on in this paper.
3.1.2. Algorithm Procedure
The EM algorithm procedure is shown in Figure 7.
Figure 7.
The flowchart of the EM algorithm.
3.1.3. Determination of the Initial Position for Each UAV
In this paper, the number of the UAV m is assumed to be four; thus, the GMM consists of four Gaussian distributions. Through continuous iteration of the EM algorithm, the expected 2D coordinates of each Gaussian distribution are found.
Expected coordinates are considered to be the positions with the highest fire point density; thus, is set as the initial position of the UAV k.
3.2. Improved GA Inspired by Fireworks Algorithm for Solving Multidimensional 0-1 Knapsack Problem
According to the previously established model, the reconnaissance task can be assigned to each UAV after obtaining the initial position of each UAV. Due to the large scale of the problem, an improved GA based on the FWA is proposed here to increase the solution speed. That means the MKP problem is solved with an FW–GA hybrid algorithm.
3.2.1. Fundamental Theory of FWA
- Fundamental theory
Inspired by the process of fireworks exploding, Tan and Zhu [22] proposed a brand-new swarm intelligence algorithm, FWA, in 2010. FWA is a very effective method to solve optimization problems. FWA considers the complex and huge solution space to be like a dark night sky and fireworks to represent a feasible solution. The process of exploding in the dark night sky and generating a large number of sparks is considered to be the process of searching for optimal solutions in the solution space around the feasible solutions. Fireworks in the night sky constantly “explode” in the night sky, searching for the optimal solution in the solution space.
- 2.
- Operator analysis of fireworks algorithm
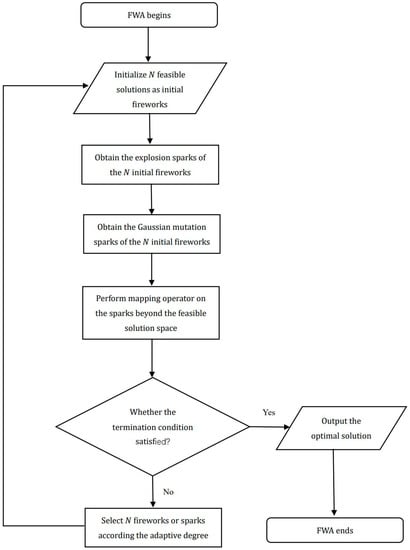
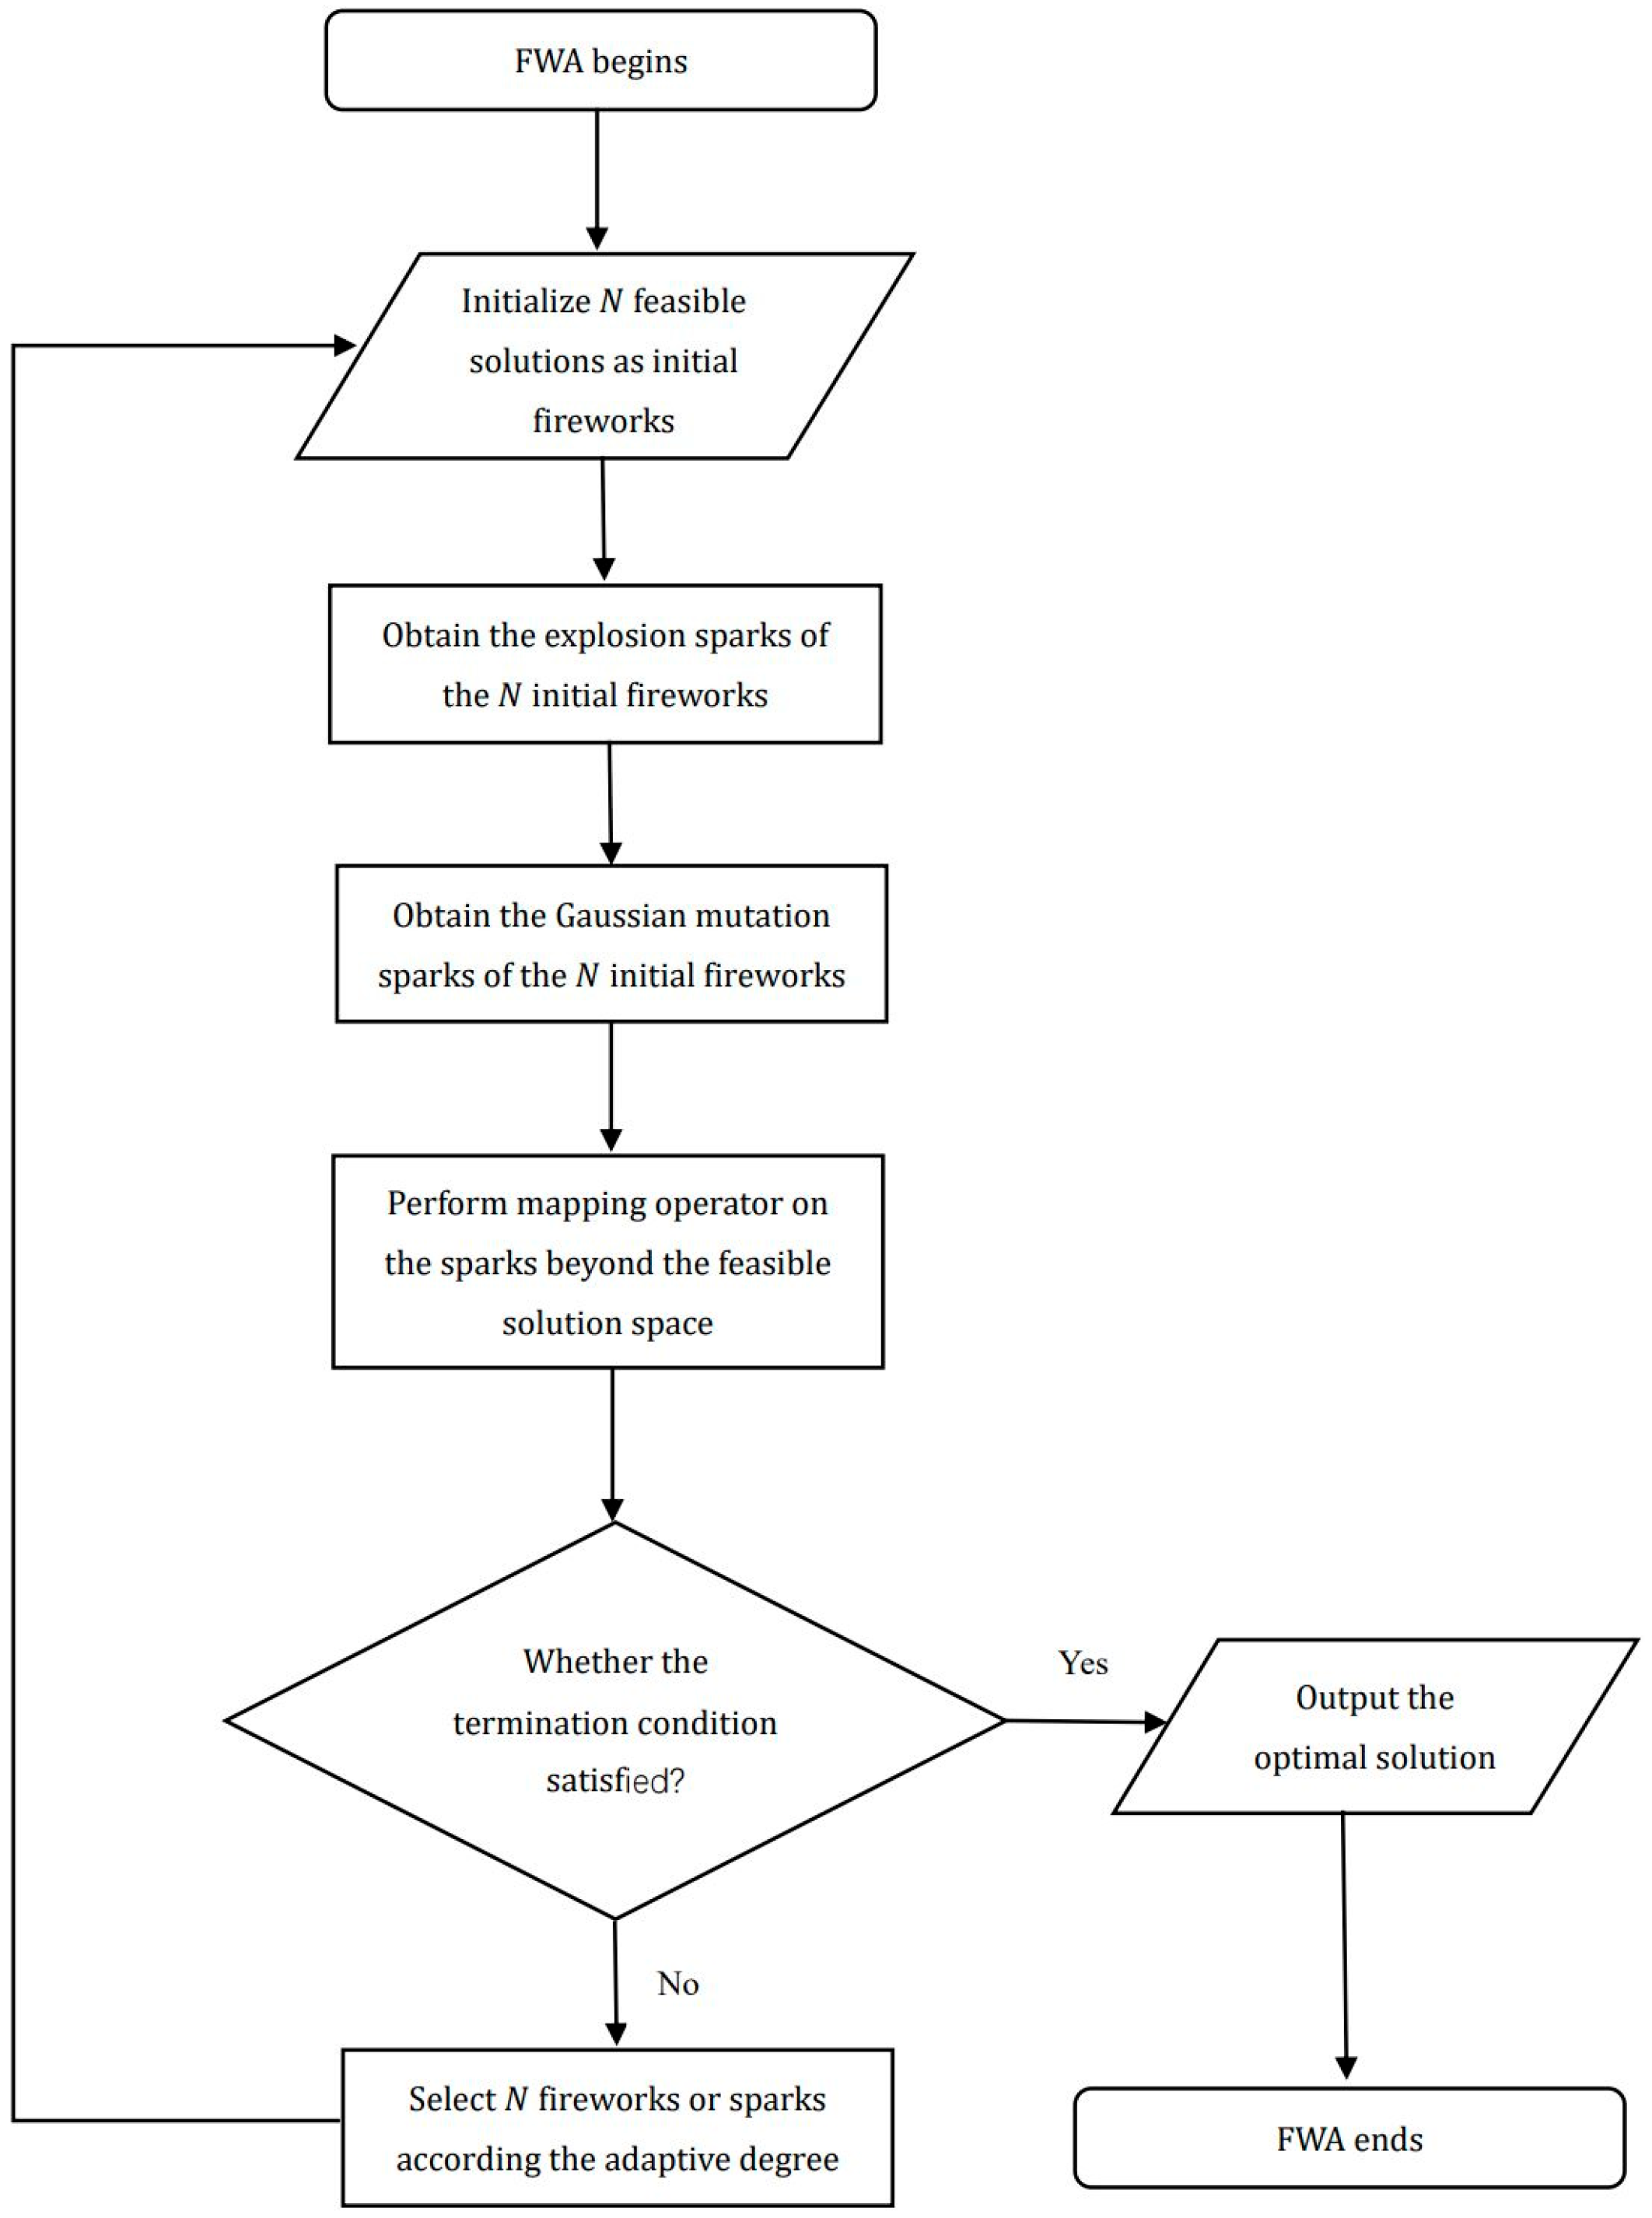
The FWA mainly consists of the explosion operator, Gaussian mutation operator, mapping operator and selection operator. The performance of the operator in the algorithm directly determines the optimization performance of the FWA.
- (1)
- Explosion operator
The explosion operator is the core of the FWA and is also the primary way of generating explosive sparks from the initial fireworks as well as searching for optimal solutions in the solution space. The explosion radius and number of exploding sparks for one firework are determined based on the firework’s adaptive degree and the adaptive degree of other fireworks in the fireworks population. It can make a reasonable allocation of resources to balance local search capability with global search capability. If a firework has a high adaptive degree, then the possibility of a global optimal solution in its neighborhood will be much higher. Thus, more resources will be assigned to the firework to generate more sparks to find the global optimal solution in its neighborhood. For fireworks with low adaptive degrees, fewer resources will be assigned for them.
First, the adaptive degree of the firework i is defined as . Then, the explosion radius and the number of exploding sparks of the firework i can be calculated as follows:
where is the maximum adaptive degree, N is the number of individuals in the fireworks population, is a small quantity to make sure the value of the denominator is not 0 and is an adjustment coefficient to adjust the explosion radius.
In Equation (18), is the minimum adaptive degree and is also an adjustment coefficient to adjust the number of exploding sparks. The meanings of the remaining parameters are the same as in Equation (17).
To prevent too few sparks being generated from fireworks with low fitness and too many sparks being generated from fireworks with high fitness, the number of sparks produced is limited in the following fireworks algorithm:
where a and b are two constant coefficients and “round” represents the rounding function.
- (2)
- Gaussian mutation operator
In order to avoid the local optimum problem in the optimization process and increase the diversity of the spark population, Gaussian mutation is introduced in the process of generating exploding sparks. The specific mathematical expression of Gaussian mutation is as follows:
where is the k-dimensional coding value of the firework i in the fireworks population and is a one-dimensional Gaussian distribution with a mean of 1 and a variance of 1.
- (3)
- Selection operator
The selection operator here is similar to the selection operator in the GA. We will introduce it in detail in the next section.
- 3.
- Algorithm Procedure
The FWA procedure is shown in Figure 8.
Figure 8.
The flowchart of the FWA.
3.2.2. Improved GA for Solving Multidimensional 0-1 Knapsack Problem
- Fundamental theory
The GA is a computing model based on computer technology. It was developed based on Darwin’s theory of evolution and Mendel’s genetic law. Its essence is an efficient, parallel global search algorithm to find the optimal solution by simulating the natural selection of genes and the evolution of populations in nature.
The GA has been widely adopted to solve the multidimensional knapsack problem [31,33]. However, the standard GA has the shortcomings of high computational complexity, slow convergence speed and ease of falling into local optimal solutions. Those problems are unacceptable in forest fire reconnaissance. The fire reconnaissance task assignment problem requires a faster solving speed to execute fire reconnaissance more quickly and efficiently, thereby reducing economic losses. Therefore, the standard GA is obviously difficult to use to meet the requirements of solving speed and optimization for the fire reconnaissance task assignment problem. Inspired by the fireworks algorithm, an improved GA is proposed based on the FWA to balance its solving speed and optimization for the fire reconnaissance task assignment problem. At the same time, elite opposition-based learning and the greedy selection operator are introduced to further improve the convergence speed and optimization ability of the algorithm.
- 2.
- Process of the improved algorithm
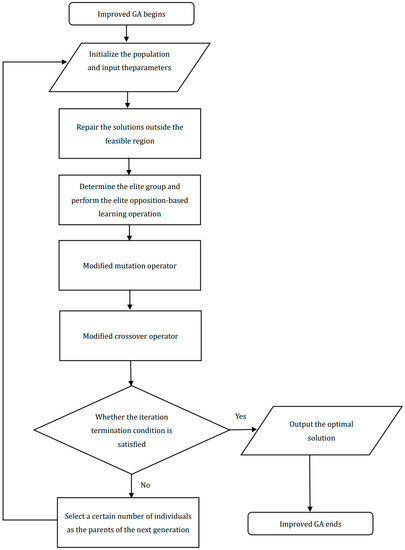
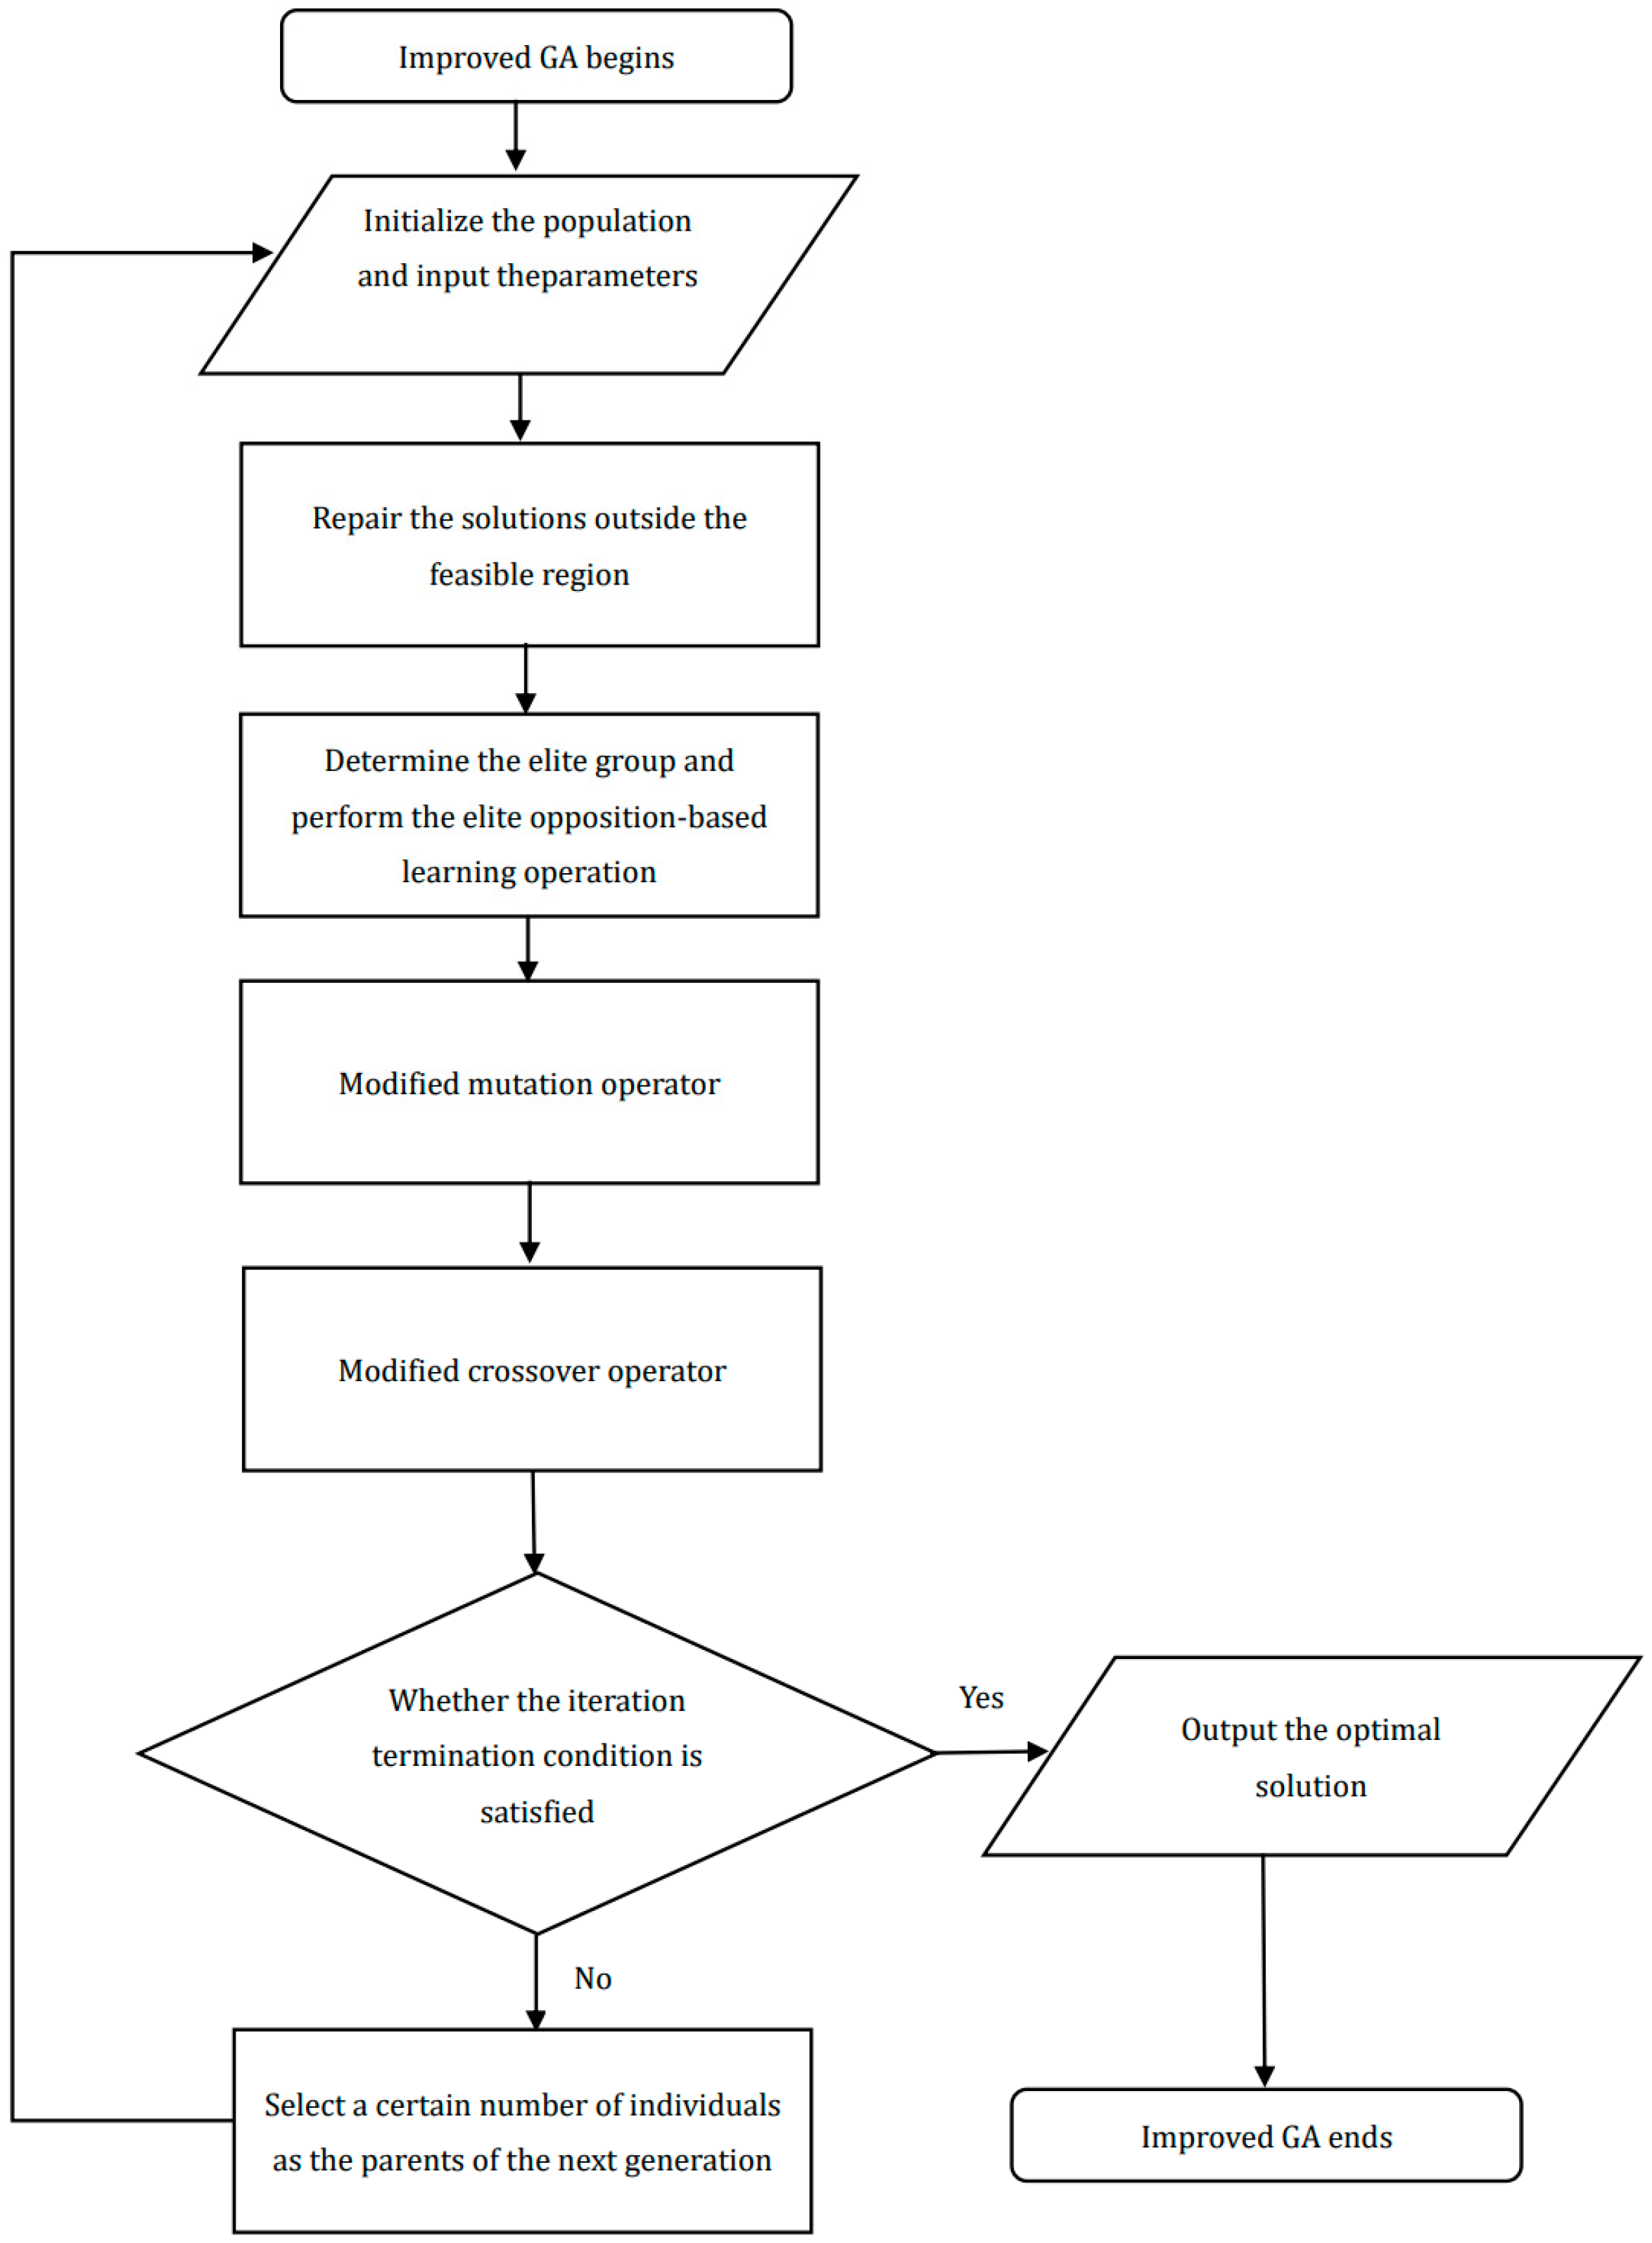
Figure 9 is the flow diagram of the FW–GA hybrid algorithm in this paper. Whether in the improved GA or the standard GA, the GA is the process of optimization via computer simulation of the evolutionary process. First, a digital coding scheme is needed to initialize the population. Then, the fitness of each individual is evaluated using the fitness function, and the individual with the highest fitness is selected based on the selection function. At the same time, a mutation operator and a crossover operator are introduced to increase the genetic diversity of the population.
Figure 9.
The flowchart of the improved GA.
The FW–GA hybrid algorithm is mainly inspired by the spark radius and spark number in FWA, and its mutation and crossover operators are improved. When the individual fitness in the population is high, there is a greater possibility of finding the global optimal solution in its vicinity; thus, more offspring are generated in a smaller solution space nearby. Conversely, if its fitness is low, the probability of finding the global optimal solution nearby is low; thus, fewer offspring are generated in a wider range nearby to explore a larger solution space. The FW–GA hybrid algorithm takes into account both local and global optimization abilities, greatly improves the utilization of computing resources compared to standard GA and improves both its speed of solving and its optimization effectiveness.
- FW–GA hybrid algorithm coding rules
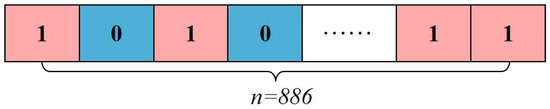
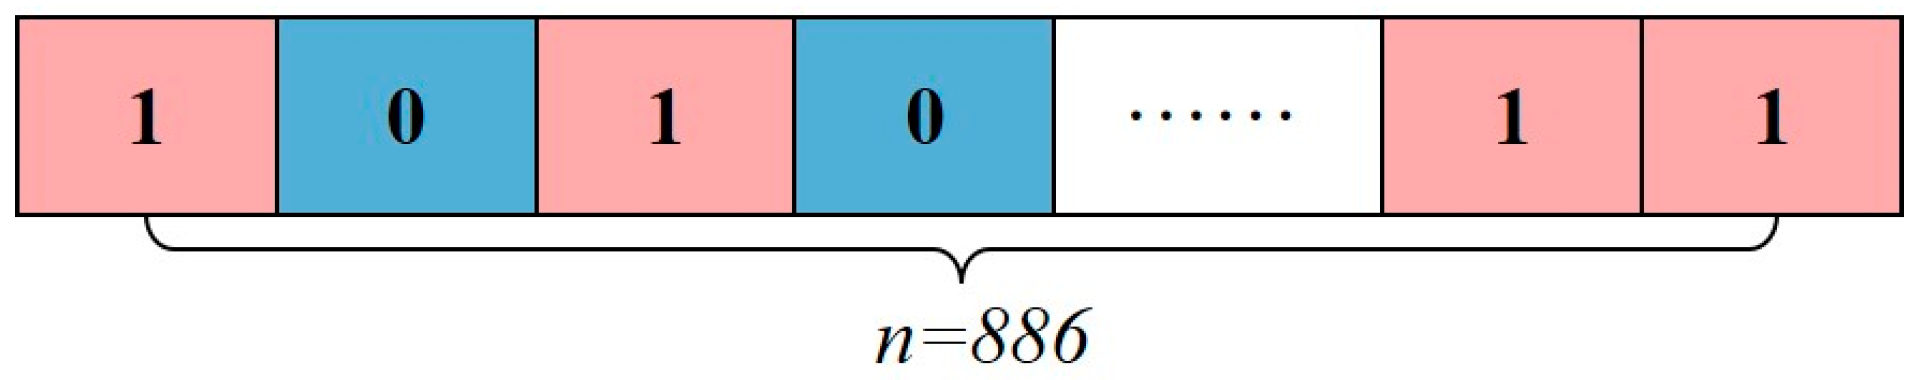
The hybrid genetic algorithm adopts the principle of binary encoding, as illustrated in Figure 10. In this encoding scheme, each chromosome represents a feasible solution, and the number of gene fragments in the chromosome, denoted as “n”, represents the number of reconnaissance tasks that need to be assigned. Specifically, a binary encoding of 1 indicates that the UAV should execute the corresponding reconnaissance task, whereas a binary encoding of 0 indicates that the UAV should not execute the task. This encoding strategy has been widely used in scientific research and has been proven to be effective.
Figure 10.
Coding schematic.
- Population initialization
As the chosen background for fire reconnaissance comprises a total of n fire points, a random binary matrix is generated by a computer, where is the population size. This matrix represents different solutions for a UAV, with each solution consisting of 886 pieces of information, which correspond to 886 tasks that need to be assigned.
- Repair Operator
Here, a concept of profit density is introduced, and the flight range constraint is taken as an example to explain the concept of profit density:
where is the profit density, , , , , and are as defined in Equations (1) and (3) and is the limit value defined in Equation (4). When solutions beyond the feasible space arise, they will be remoted one by one by setting the gene fragment of the corresponding task point to 0 for individuals with lower profits. This process is repeated until all individuals in the population are within the feasible solution space.
- Fitness calculation
To ensure the quality of solutions and guide subsequent mutation, crossover and selection, it is necessary to calculate the fitness of individuals. For the knapsack model introduced in Section 2, the objective function value is selected as the fitness. By iterating and optimizing the fitness function, high-quality solutions can be obtained.
- Elite opposition-based learning operator
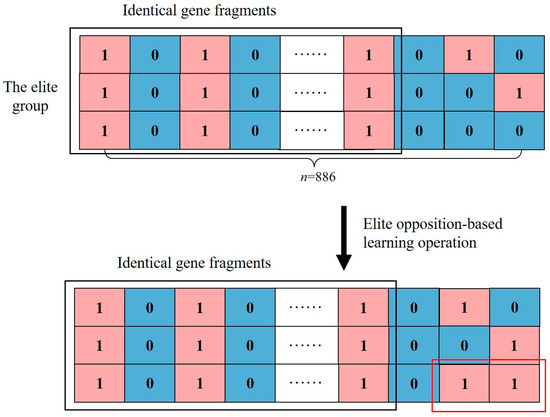
To improve the convergence rate of the algorithm, an elite opposition-based learning strategy is introduced. In the current study, the iteration direction of the swarm intelligence algorithm is mostly dominated by the elite solution population, and making full use of the elite solution information is the key to increase the iteration speed. The basic idea is shown as follows:
The elite group is defined as:
where is the set of all feasible solutions and represents the elite solution in .
Here, the individual with fitness greater than 95% of the maximum fitness in the pop set can be considered an elite individual.
In Equation (23), is the fitness of the elite individual and is the maximum fitness in .
For the multidimensional 0-1 Knapsack problem, the reverse solution of binary encoding can be expressed as:
where is the coding value of individual in dimension and is the value of the reverse solution of individual in dimension .
According to the binary elite opposition-based learning strategy, the dimensions with differences are reversed to obtain a new individual.
At the same time, the step length of the reverse solution is defined:
where is the number of reverse solution dimensions, is a small quantity and is an integer function. After obtaining the step length of the reverse solution, dimensions are randomly selected, and then the reverse solution is obtained. In the elite reverse decoding process shown in Figure 11, two segments were randomly selected from the non-identical encoding area of the third individual for reverse binary operation, namely and with values of and , respectively.
Figure 11.
Elite opposition-based learning strategy schematic.
- Mutation operator
In the standard GA, mutation is achieved by randomly mutating different gene coding positions with equal probability. This approach can increase the genetic diversity of the population to a certain extent. However, it may slow down the iteration and make it difficult to converge to the global optimal solution if the mutation probability remains constant when the fitness of the population is generally high at the end of the iteration. In the standard GA, each parent generally produces a certain number of offspring after mutation. It is well-known that the probability of producing offspring with high fitness is generally higher for a parent with higher fitness and lower for a parent with lower fitness. If each parent produces the same number of offspring, it will waste a lot of computational resources and may affect the final optimization result.
Intelligently regulating the mutation probability and the number of offspring produced by each parent is the key to optimize the GA and to solve the multidimensional 0-1 Knapsack problem faster and better. Inspired by the FWA, the mutation operator in the traditional GA was improved based on the concept of explosion radius and number of explosion sparks proposed by the FWA to solve the multidimensional 0-1 Knapsack problem.
Intelligently regulating mutation probability and the number of offspring produced by each parent is crucial to optimizing the GA and achieving faster and better solutions to the multidimensional 0-1 Knapsack problem. Drawing inspiration from the FWA, the mutation operator in the standard GA was enhanced by incorporating the concepts of explosion radius and number of explosion sparks from the FWA.
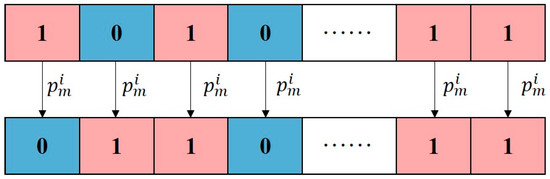
A dynamically adjustable mutation probability can be acquired from Equation (26).
In Equation (26), is the mutation probability of the parent , is the fitness of the parent , is the maximum fitness, is the number of individuals in population, is a small quantity to make sure the value of denominator is not 0 and is an adjustment coefficient to adjust mutation probability. After determining the mutation probability of each parent, equiprobable mutations are performed on each gene segment, as shown in Figure 12, where the first and second gene segments indicate successful gene mutations. Analysis of the previous fireworks algorithm shows that when individual fitness is relatively high, the mutation probability will be reduced to narrow the search range; when it is low, the mutation probability will be increased to expand the search radius and search for the optimal solution in a larger space.
Figure 12.
Mutation schematic.
At the same time, to better assign computational resources, the number of offspring produced by the parent , , is defined as follows:
In Equation (27), is the number of offspring produced by the parent , is integer function, is the fitness of parent , is the minimum fitness, is a small quantity to make sure the value of denominator is not 0, is the number of individual in the population and is also an adjustment coefficient to adjust the number of offspring. The definition of the lower and upper limits of the number of offspring is the same as the definition of the lower and upper limits of the number of fireworks in the FWA.
From Equation (27), it can be determined that the number of offspring is determined by the fitness of the parent. A parent with higher fitness is likely to be closer to the global optimal solution, and more computational resources will be allocated for it to search for the optimal solution. Conversely, a parent with lower fitness is more likely to be far from the global optimal solution; thus, less computational resources are allocated for it.
- Crossover operator
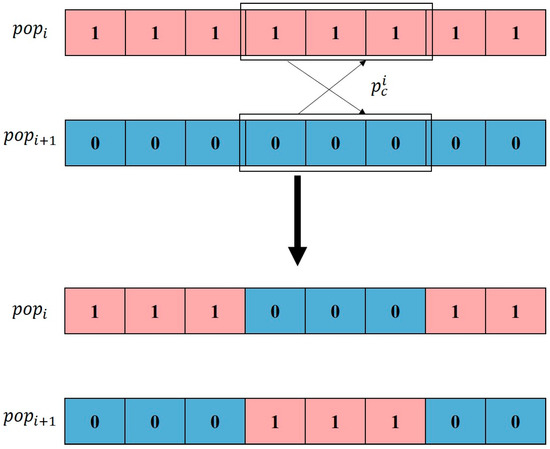
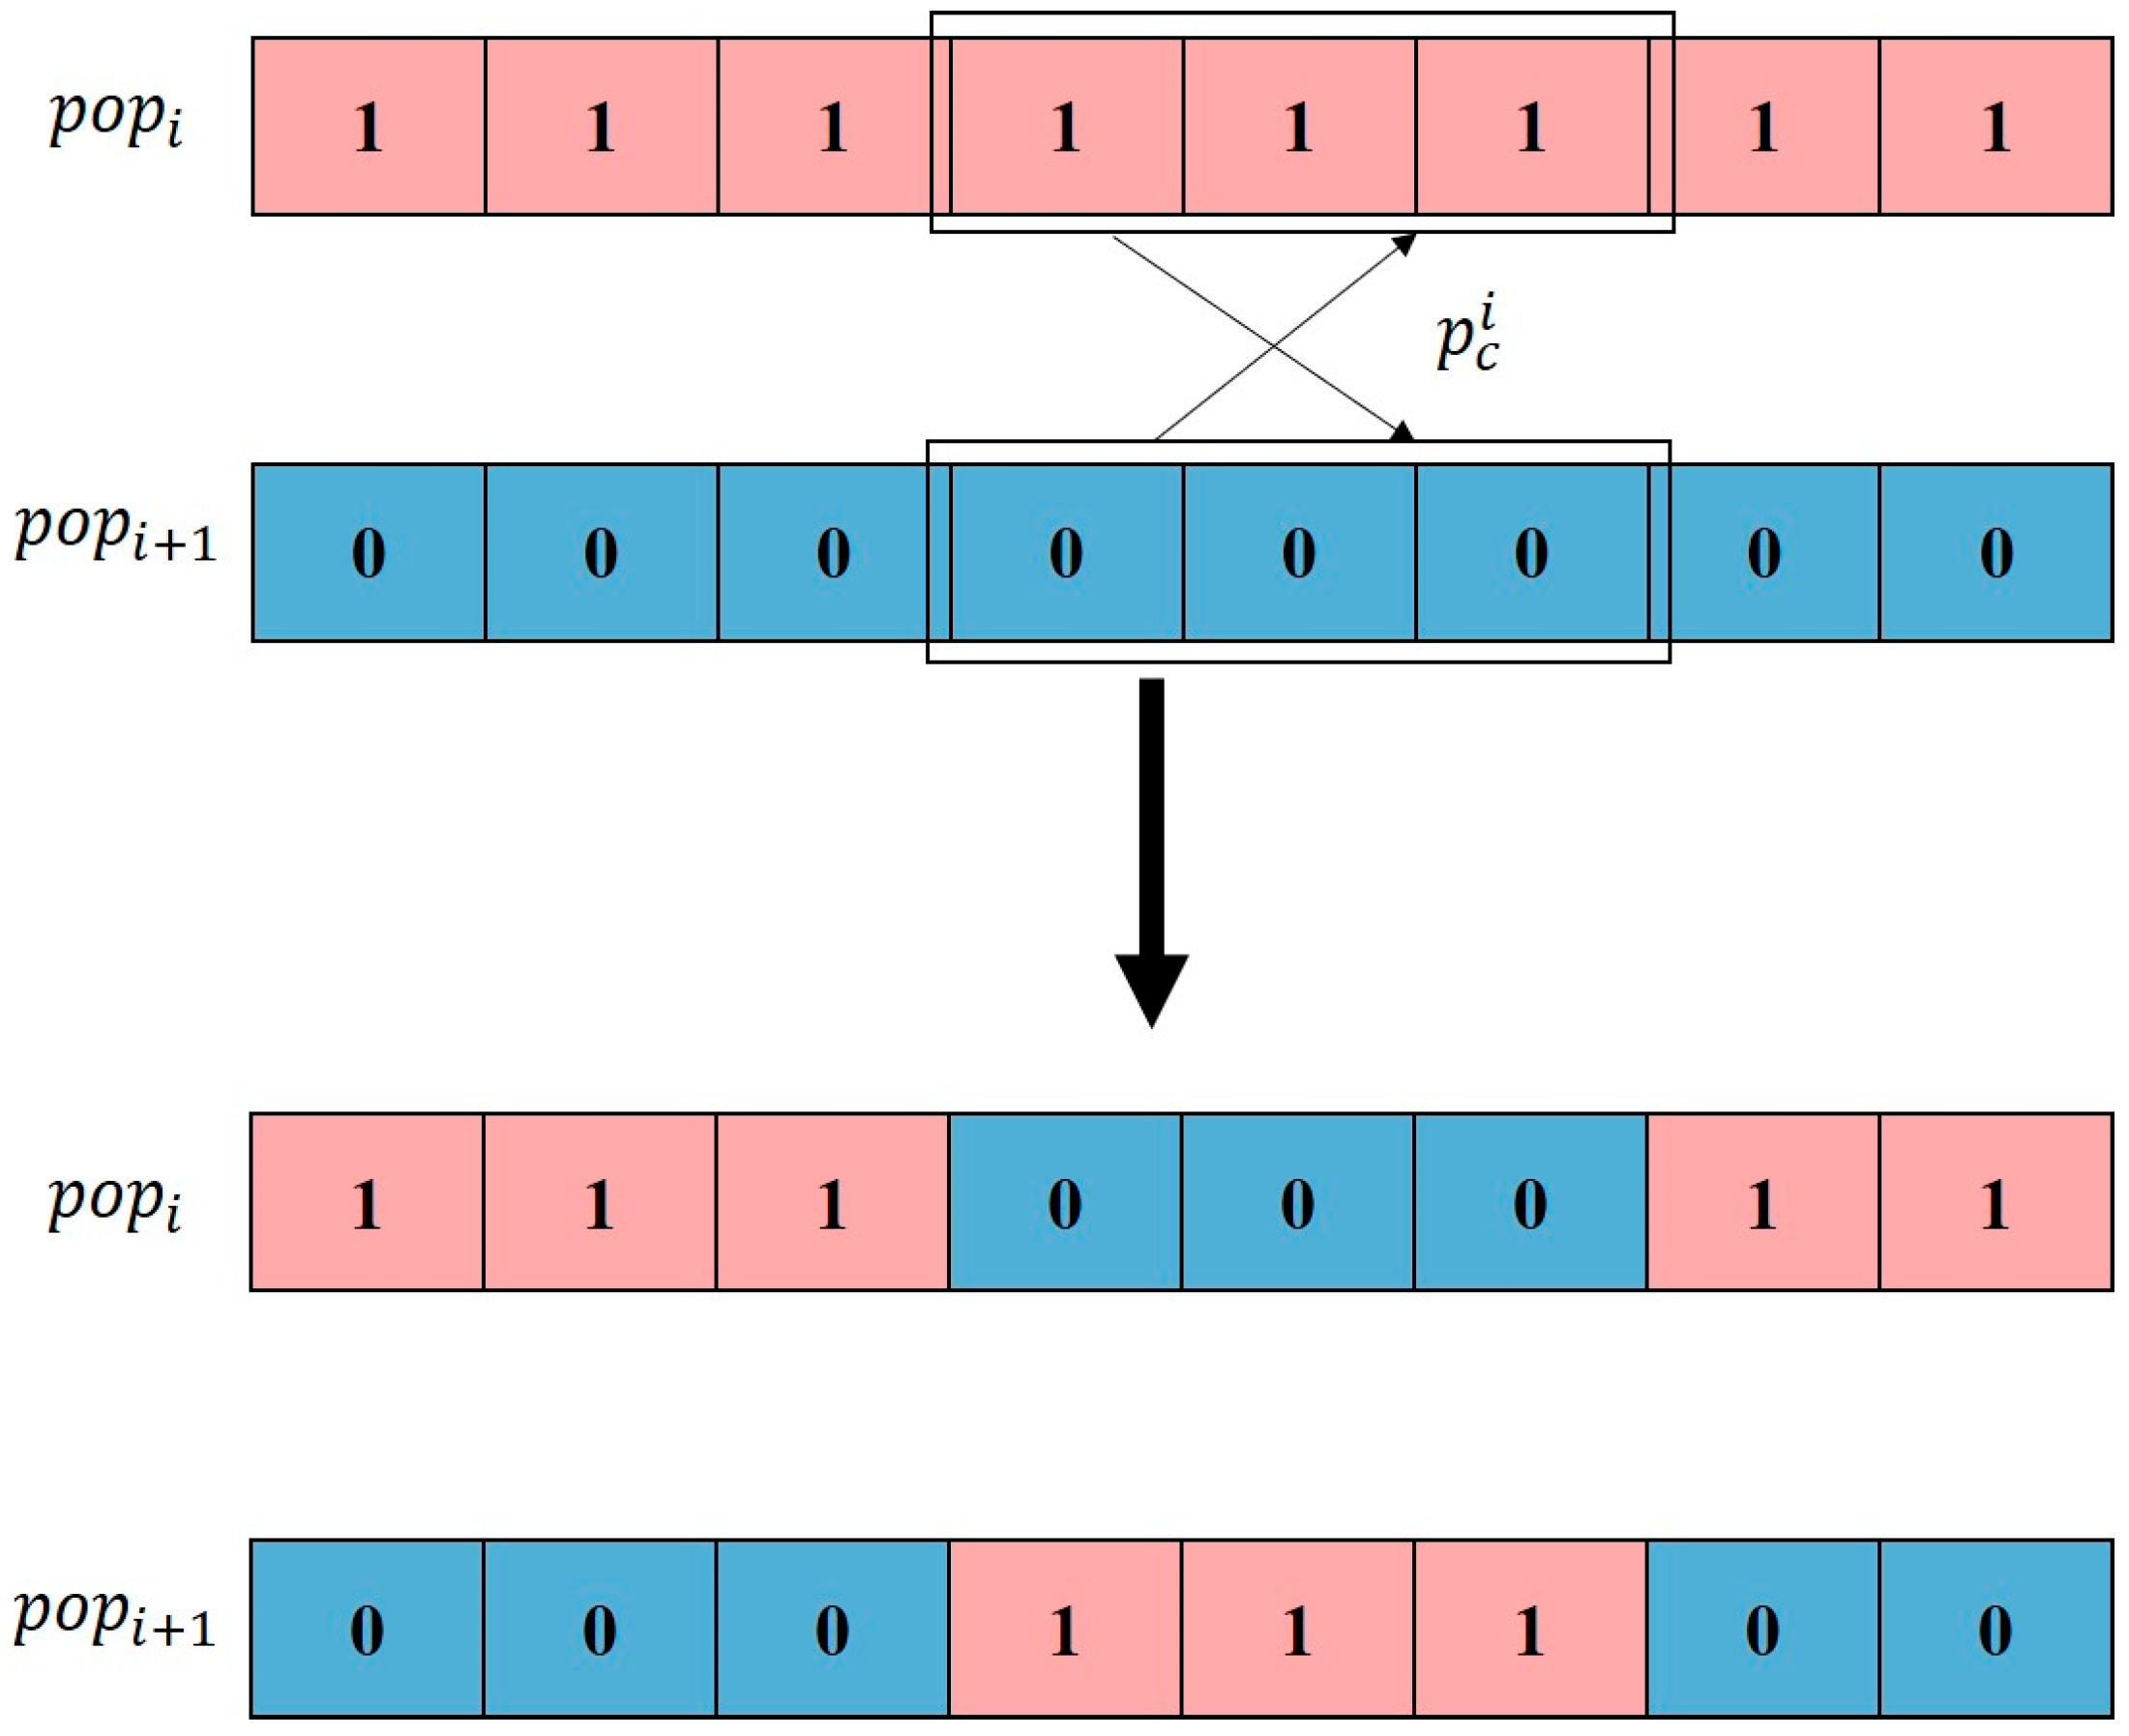
In standard GA, the crossover points and the crossover length are random, and the crossover probability is generally determined, which leads to the same dilemma as the mutation operator: the unreasonable allocation of computational resources. A method similar to the method to improve the mutation operator was applied to the improve crossover operator.
First, the crossover length and crossover probability are determined for parent .
In Equation (29), n is the number of gene fragments in the chromosome. The definitions of the variables in Equations (28) and (29) are the same as their counterparts in Equation (26). Similar to the mutation operator, the crossover length and the crossover probability are related to the fitness of the parent. For individuals with high fitness, the distance from the global optimal solution is likely to be shorter; thus, the value of crossover length and crossover probability need not be too high; on the contrary, a higher crossover probability and a longer crossover length will be adopted to search the optimal solution in a wider space.
Second, the numbers of offspring generated by each parent need to be determined, and here, a strategy similar to that in the mutation operator is also adopted:
The definition of each variable in Equation (30) is the same as in Equation (27), and the crossover operation is shown in Figure 13.
Figure 13.
Crossover schematic.
- Select operator
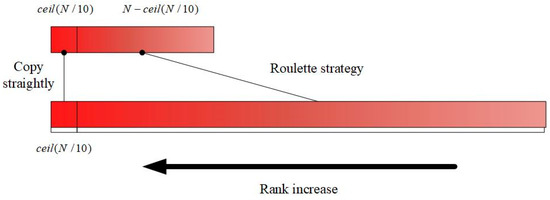
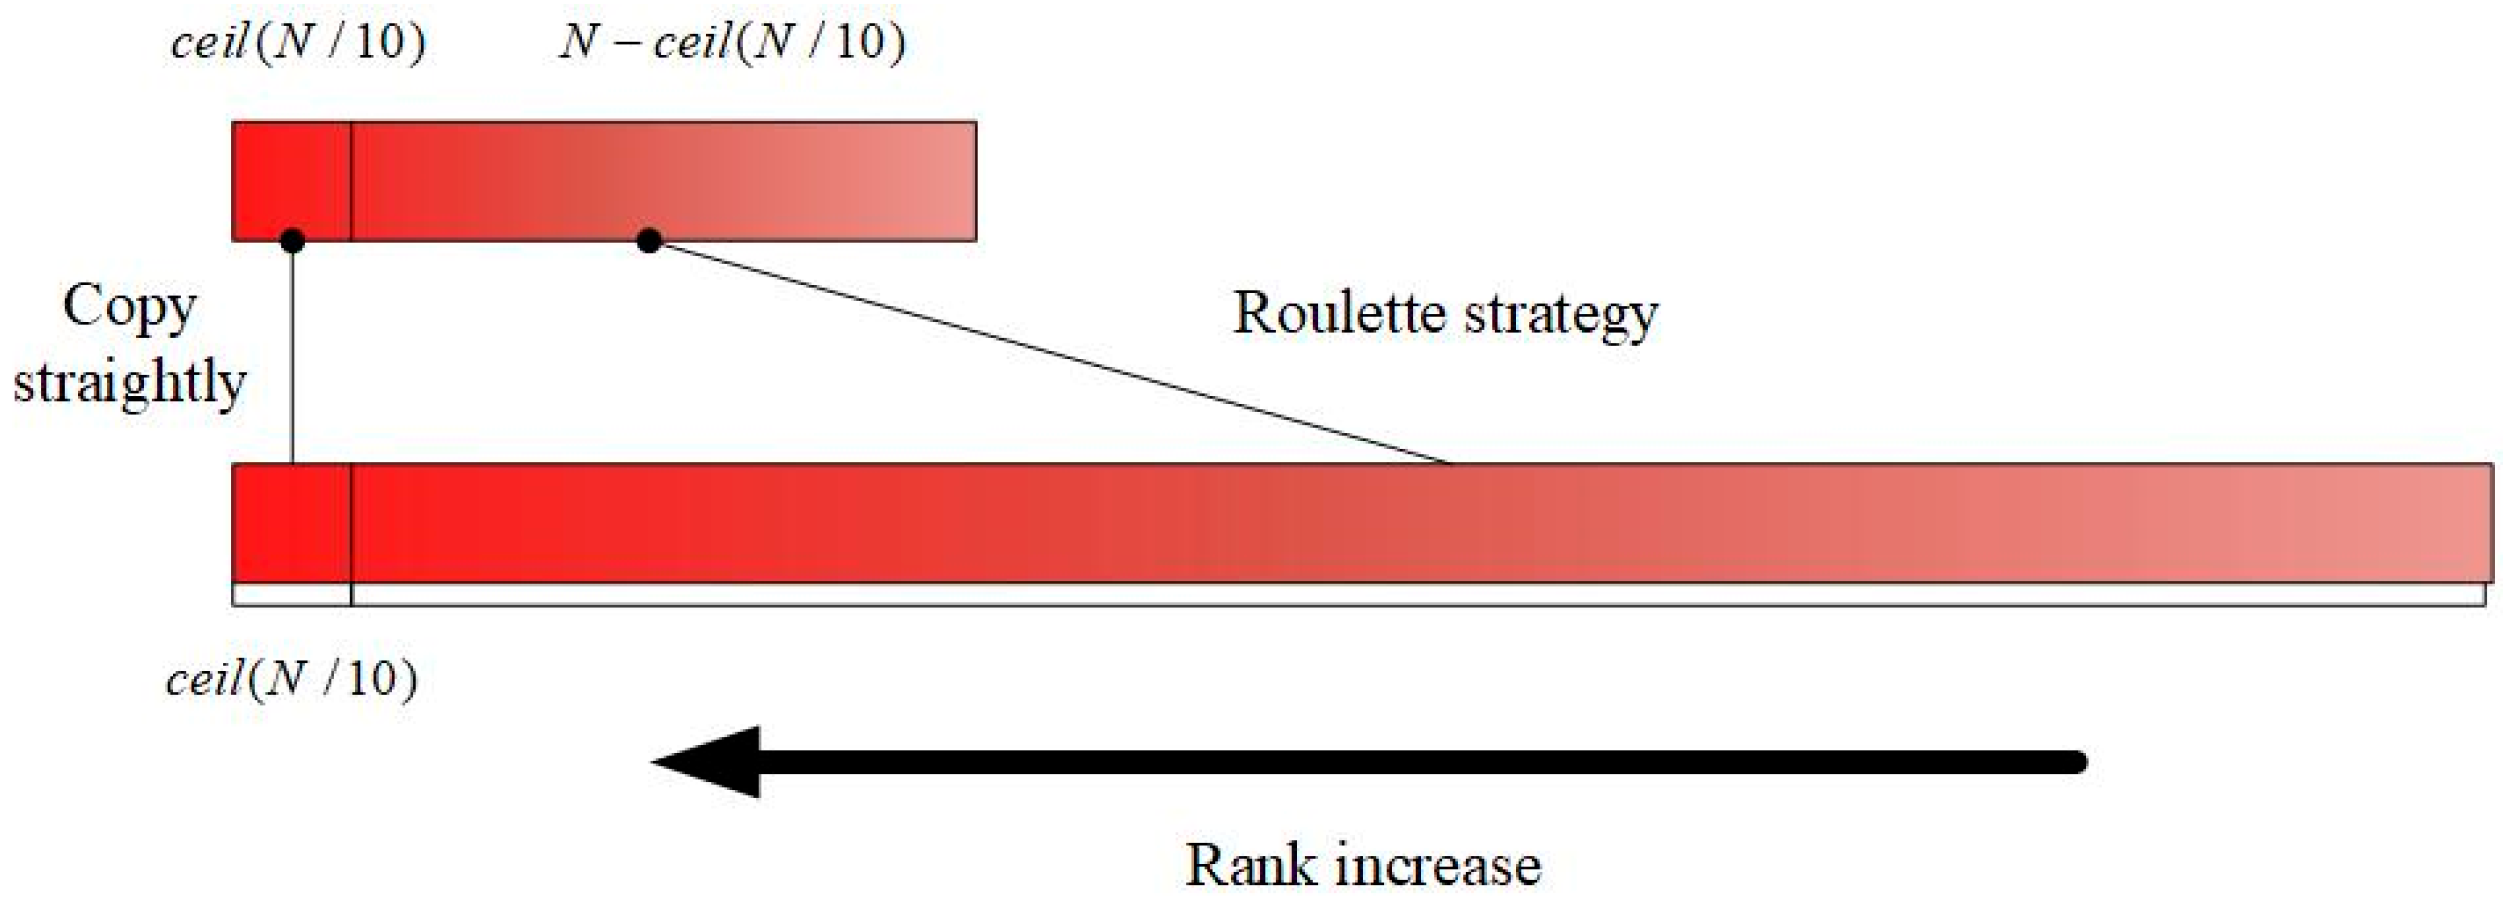
The standard GA adopts a roulette wheel selection method to select offspring for the next generation. To accelerate iteration, a greedy strategy was introduced to improve the selection operator. As it is shown in Figure 14, the top ceil(N/10) (where ceil() is the integer function) individuals ranked by fitness in each generation are preserved to the next generation without probability-based selection. Meanwhile, the roulette wheel selection method is also adopted to choose N-ceil (0.1 × N) individuals from the remaining population, thereby ensuring that the number of offspring selected in every generation is always N.
Figure 14.
Greedy selection schematic.
- Termination condition determination
There are two termination conditions for the GA–SA algorithm in this paper. The first condition is that if the ratio of the difference between the maximum fitness value of the current generation population and the previous generation population to the maximum fitness value of the current generation is less than eps, then the iteration stops. The second condition is that if the algorithm reaches the preset number of iterations, then the iteration stops.
4. Simulation Results
Because the forest fire background scenario selected for this study cannot be reproduced, simulation experiments were carried out to verify the effectiveness of the proposed model. To test the performance of the proposed mission assignment method, simulation experiments were conducted on a workstation equipped with two 2.2 GHz Intel Xeon E5-2630 v4 processors using MATLAB 2021a. The EM algorithm was applied to obtain the initial position first. Then, the Rastrigin function was adopted to test the performance of the proposed algorithm. Finally, the standard GA, FW–GA hybrid algorithm and GA–SA hybrid algorithm were separately applied to solve the MKP problem. To avoid the influence of randomness caused by the intelligent optimization algorithms on the experimental results, the method of conducting multiple independent repeated experiments was used to verify that the measurements in the experiment are unbiased. The running time, number of iterations and objective function value of the 50 independent repeated experiments were statistically analyzed to compare the advantages and disadvantages of the different algorithms.
4.1. Obtain the Initial Position of Each UAV Based on EM Algorithm
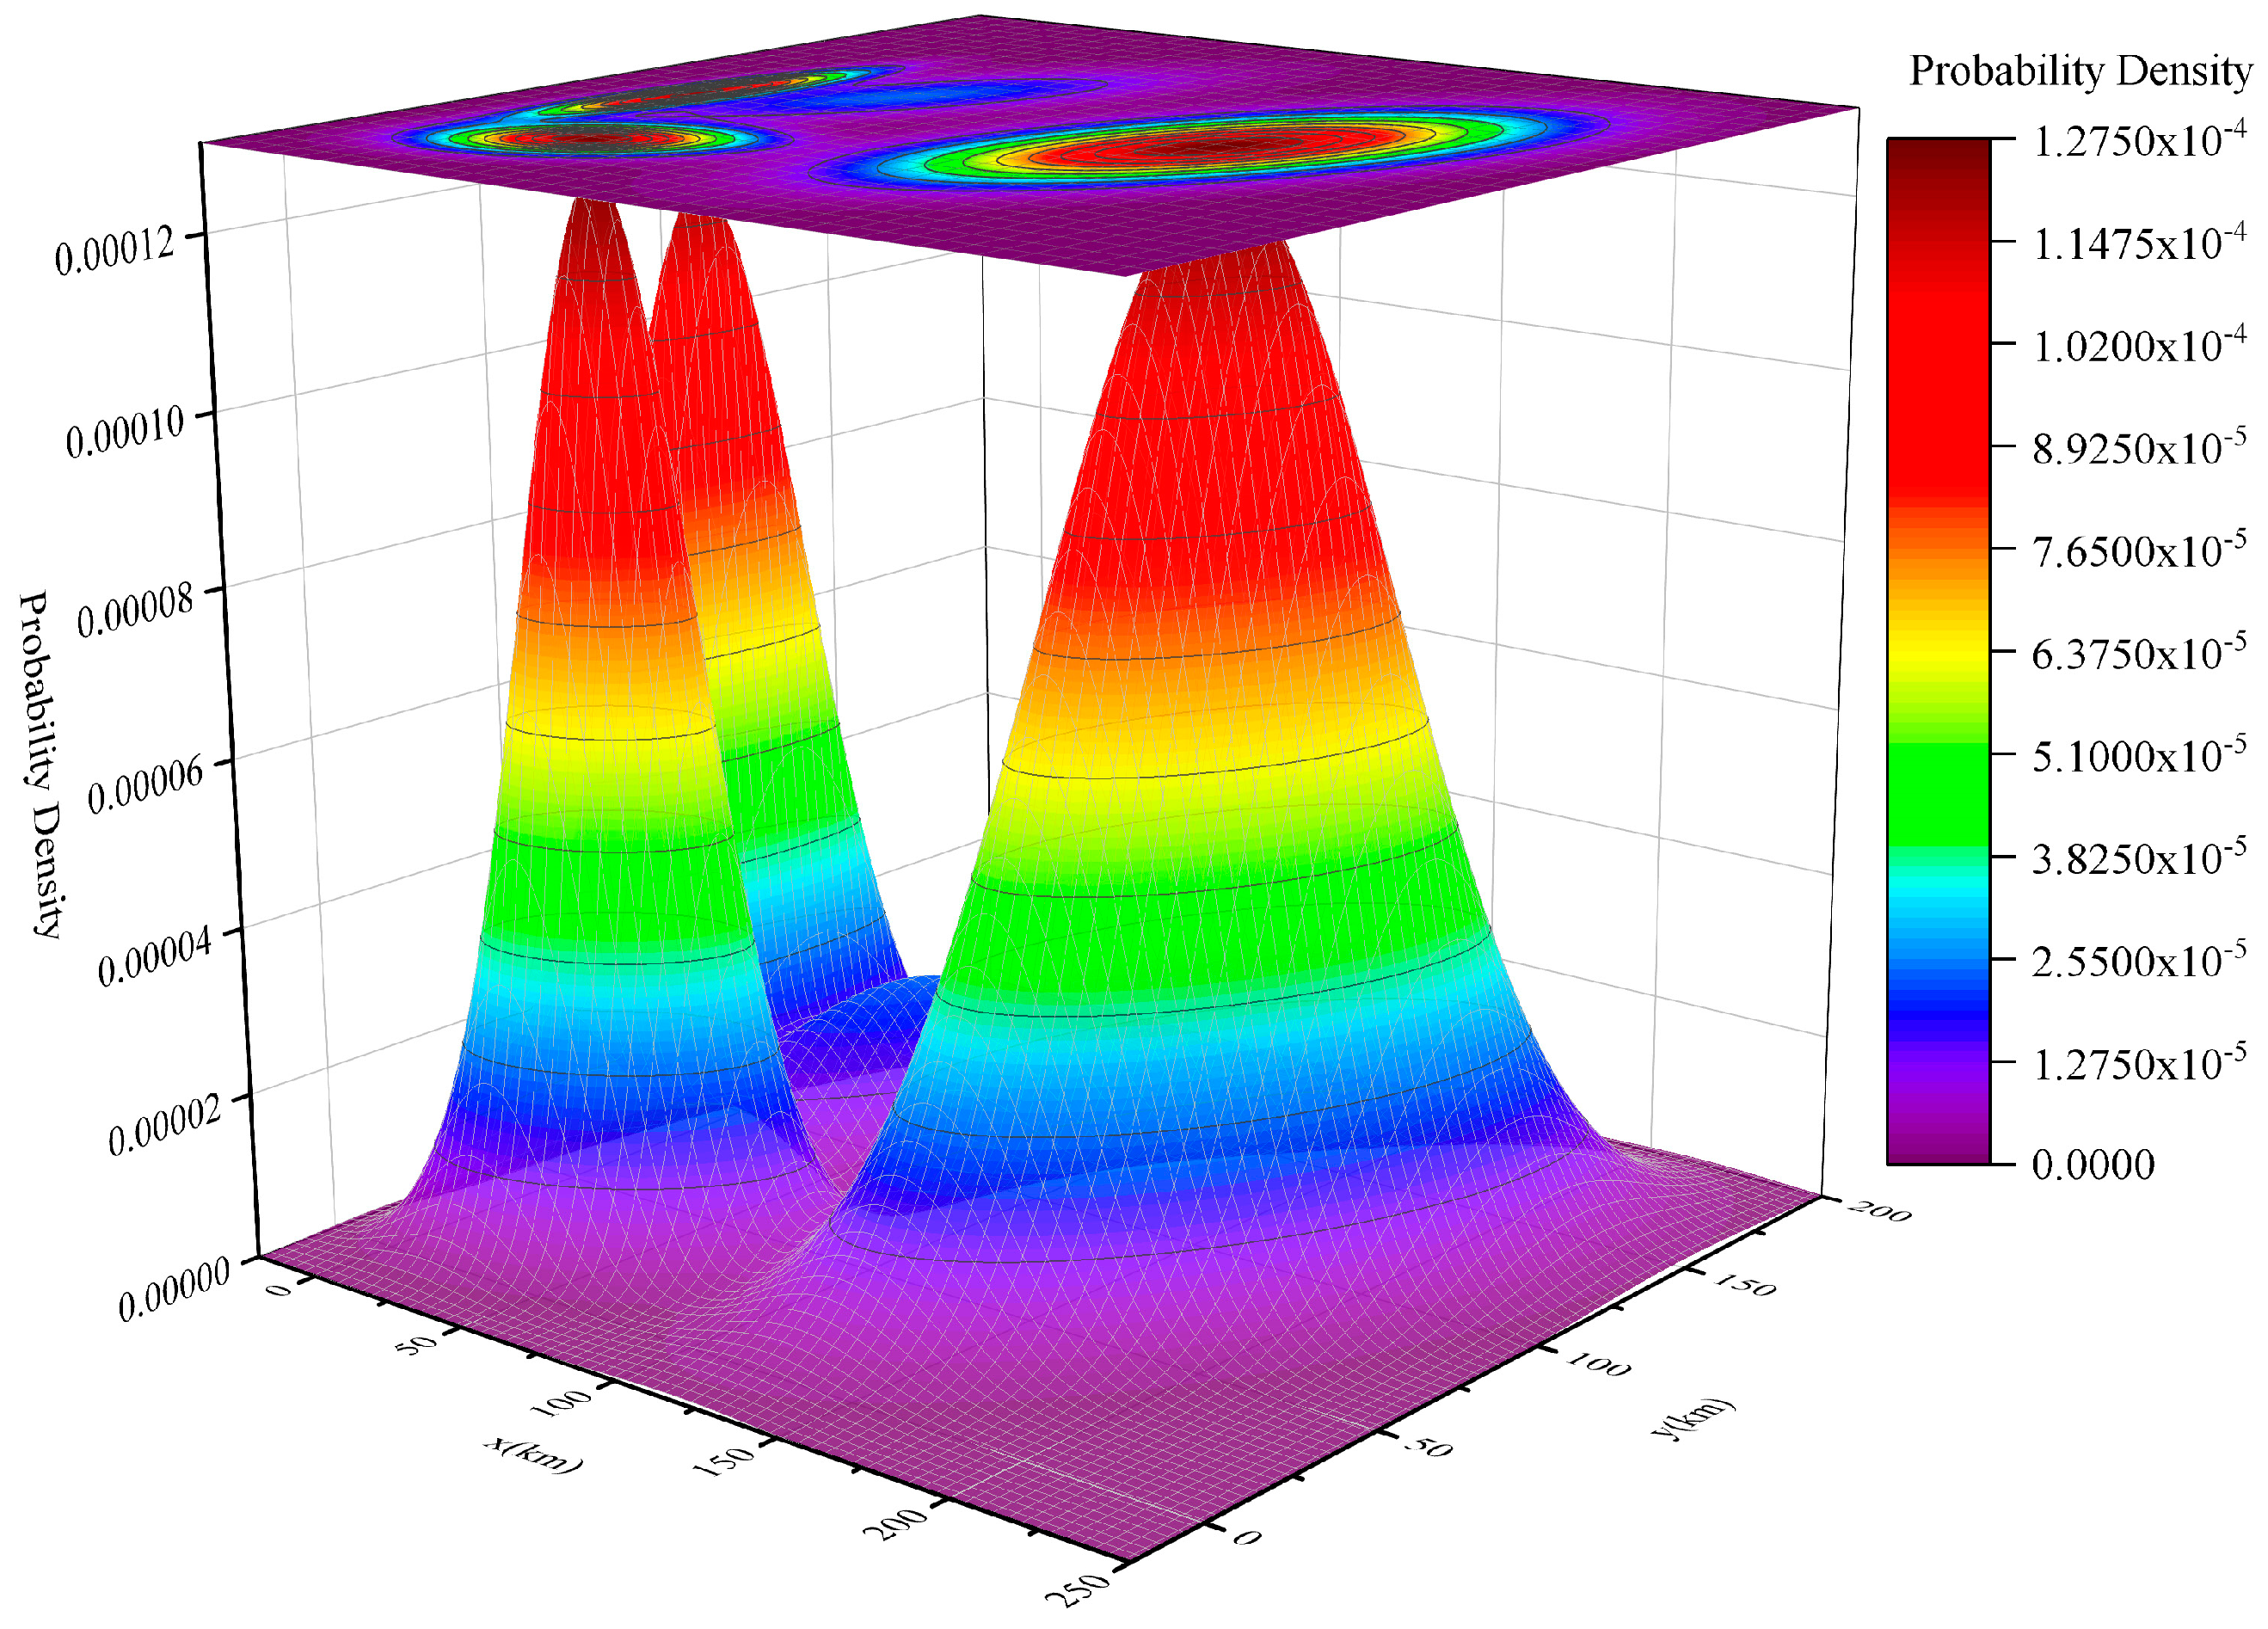
Based on the EM algorithm, the probability density function of the GMM was obtained. The probability density plot is shown in Figure 15. It can be seen that there are three higher peaks and one lower peak, indicating that there were three areas with dense distributions of fire points in the fire scene, whereas the fourth area, although not densely distributed, still had a significant number of fire points.
Figure 15.
Probability density distribution of GMM.
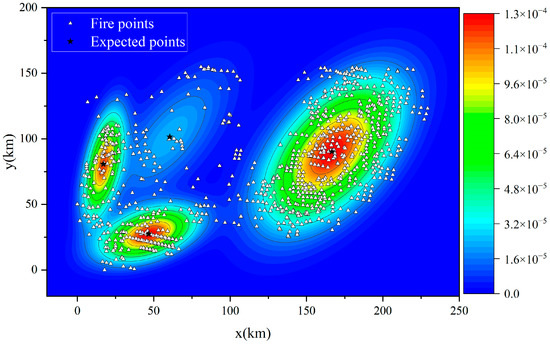
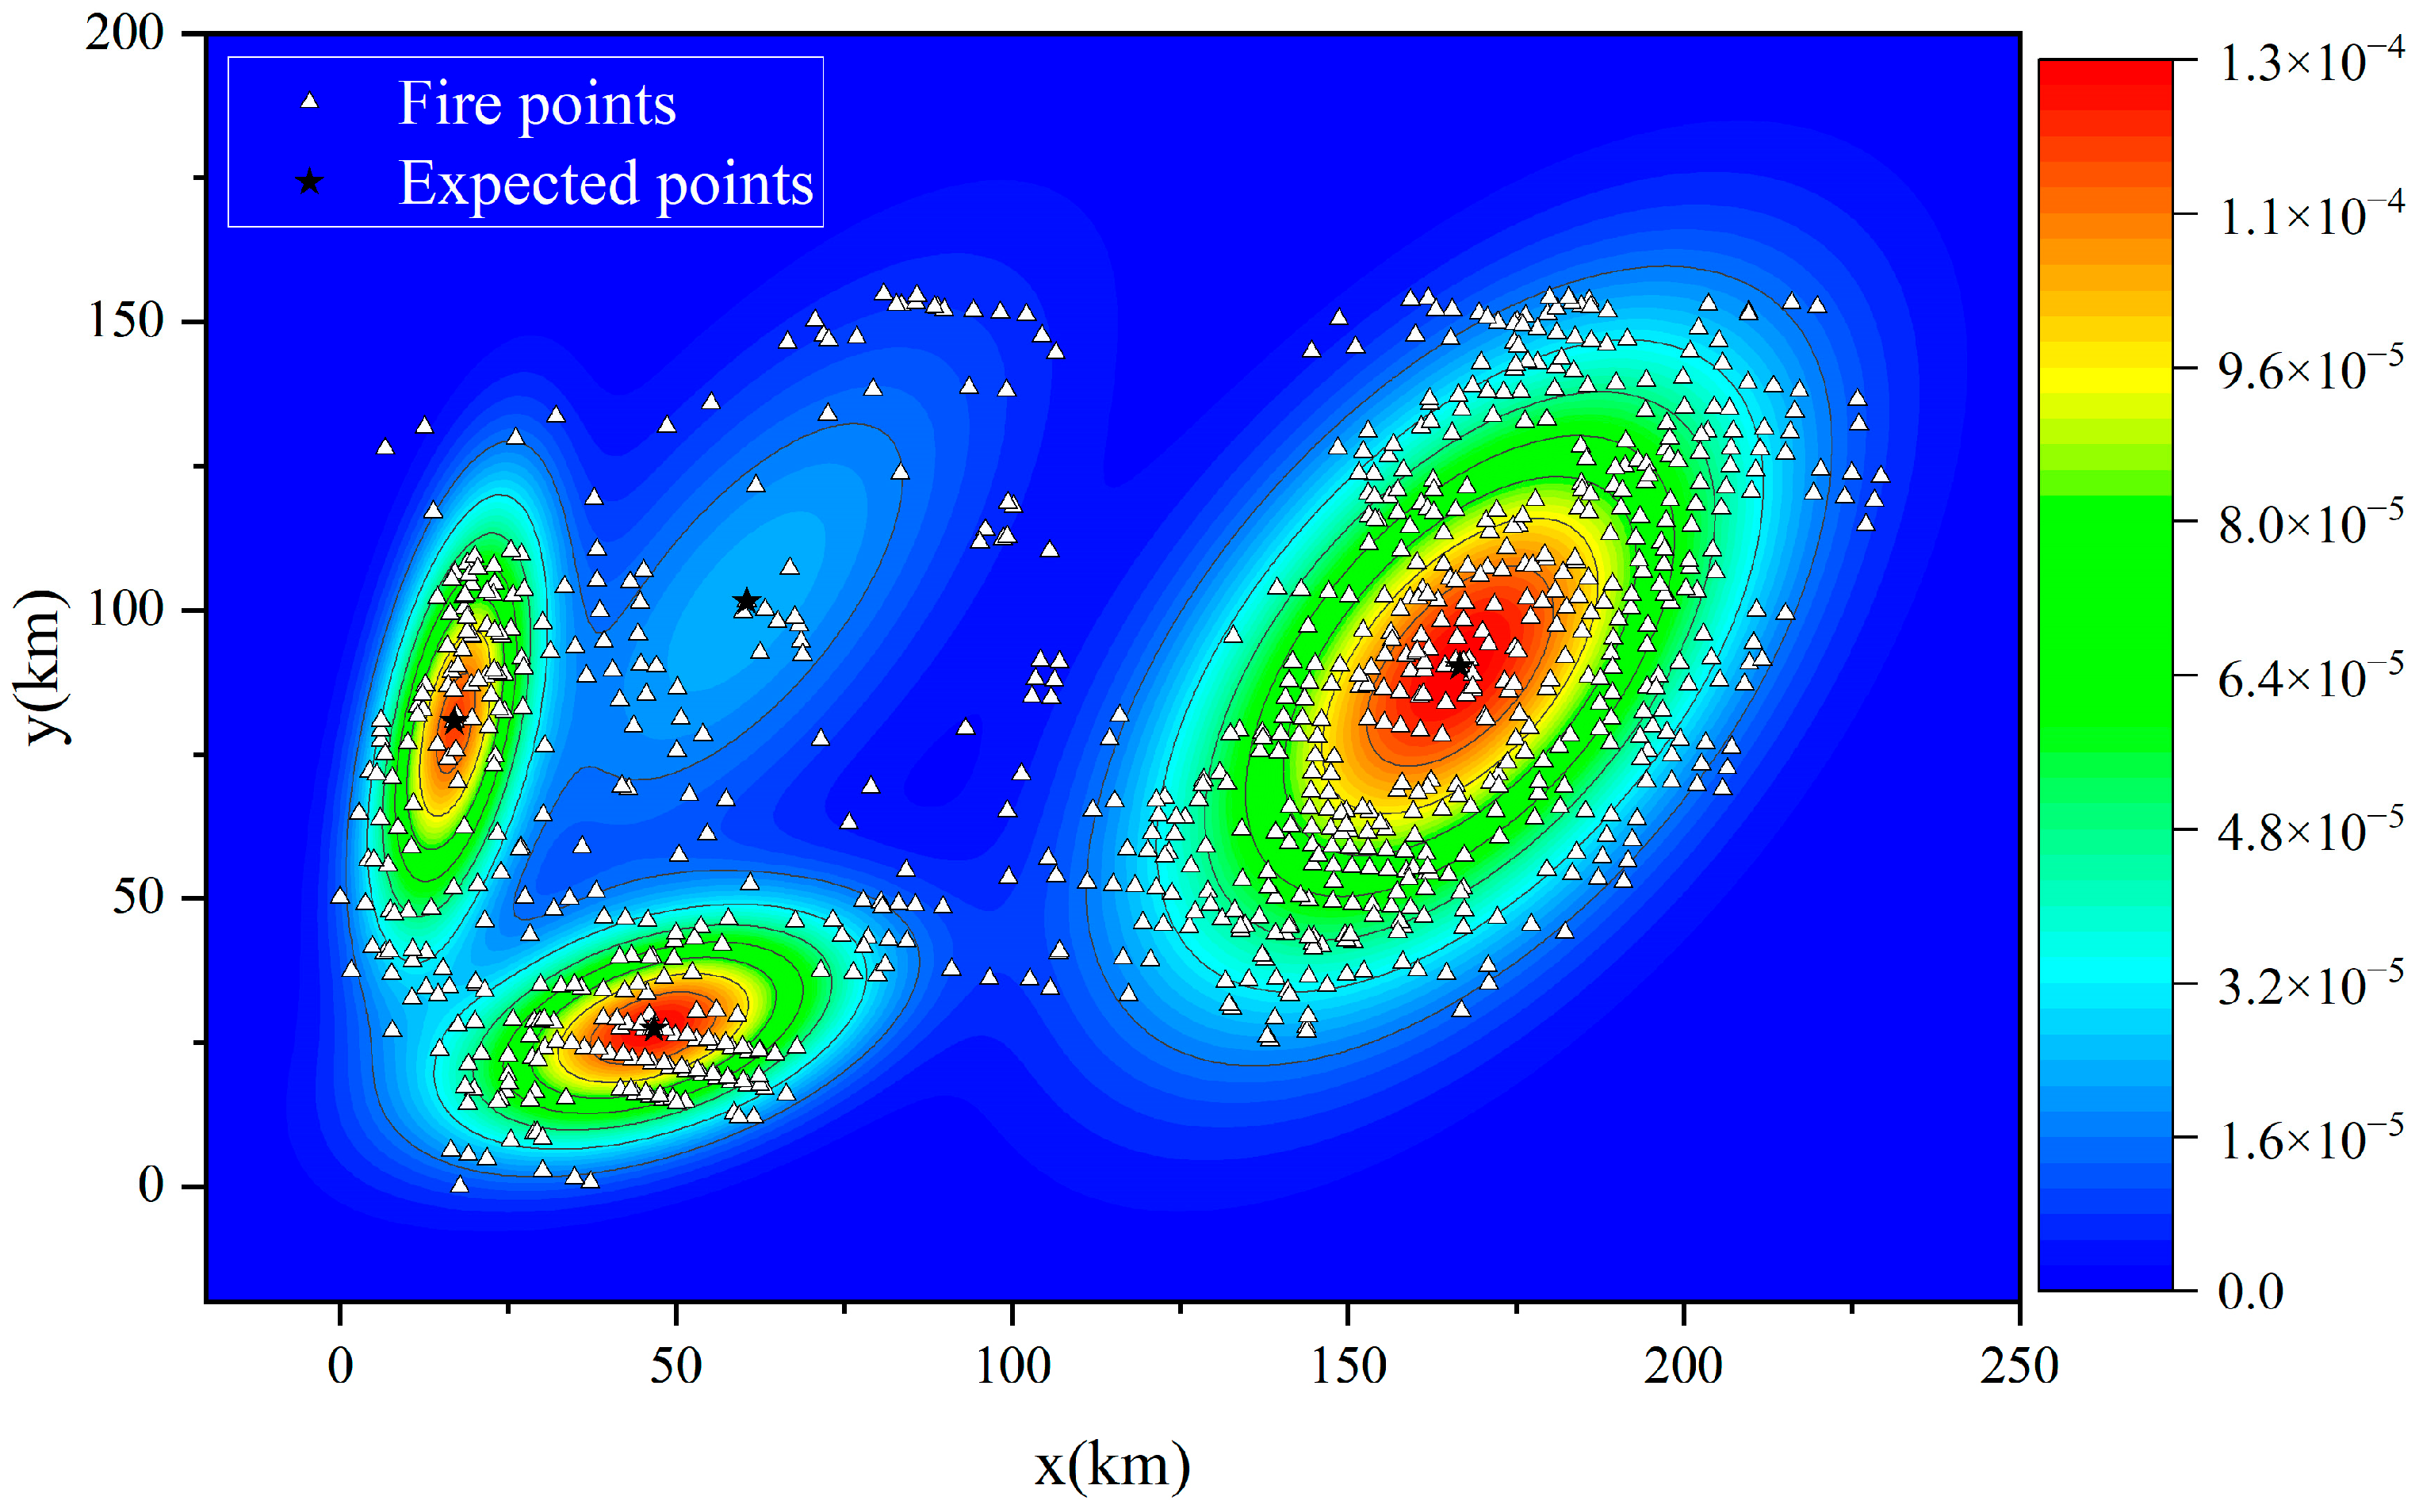
To analyze of the fitting effect, the probability density distribution of the GMM was projected to the two-dimensional plane and compared with the fire distribution. In Figure 16, it can be clearly seen that the two-dimensional GMM can fit the distribution of fire points well. Table 1 shows the main parameters of four Gaussian distributions in GMM:
Figure 16.
Two-dimensional probability density plot of GMM.
Table 1.
Parameters of each Gaussian distribution.
After clustering analysis, the 2D expected coordinates of four Gaussian distributions were set as the initial positions of each UAV.
4.2. Solve the MKP Problem Based on Intelligent Optimization Algorithms
4.2.1. Verification of Hybrid Algorithm Performance
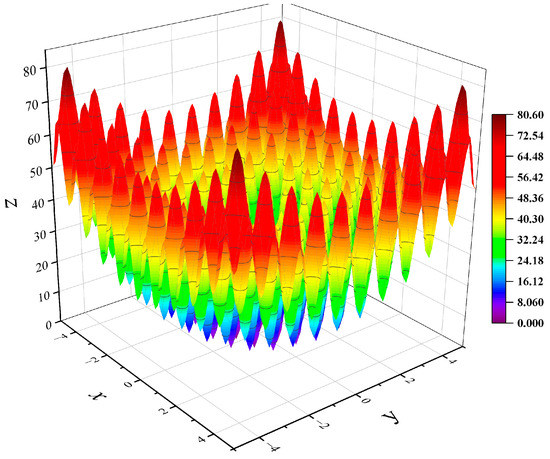
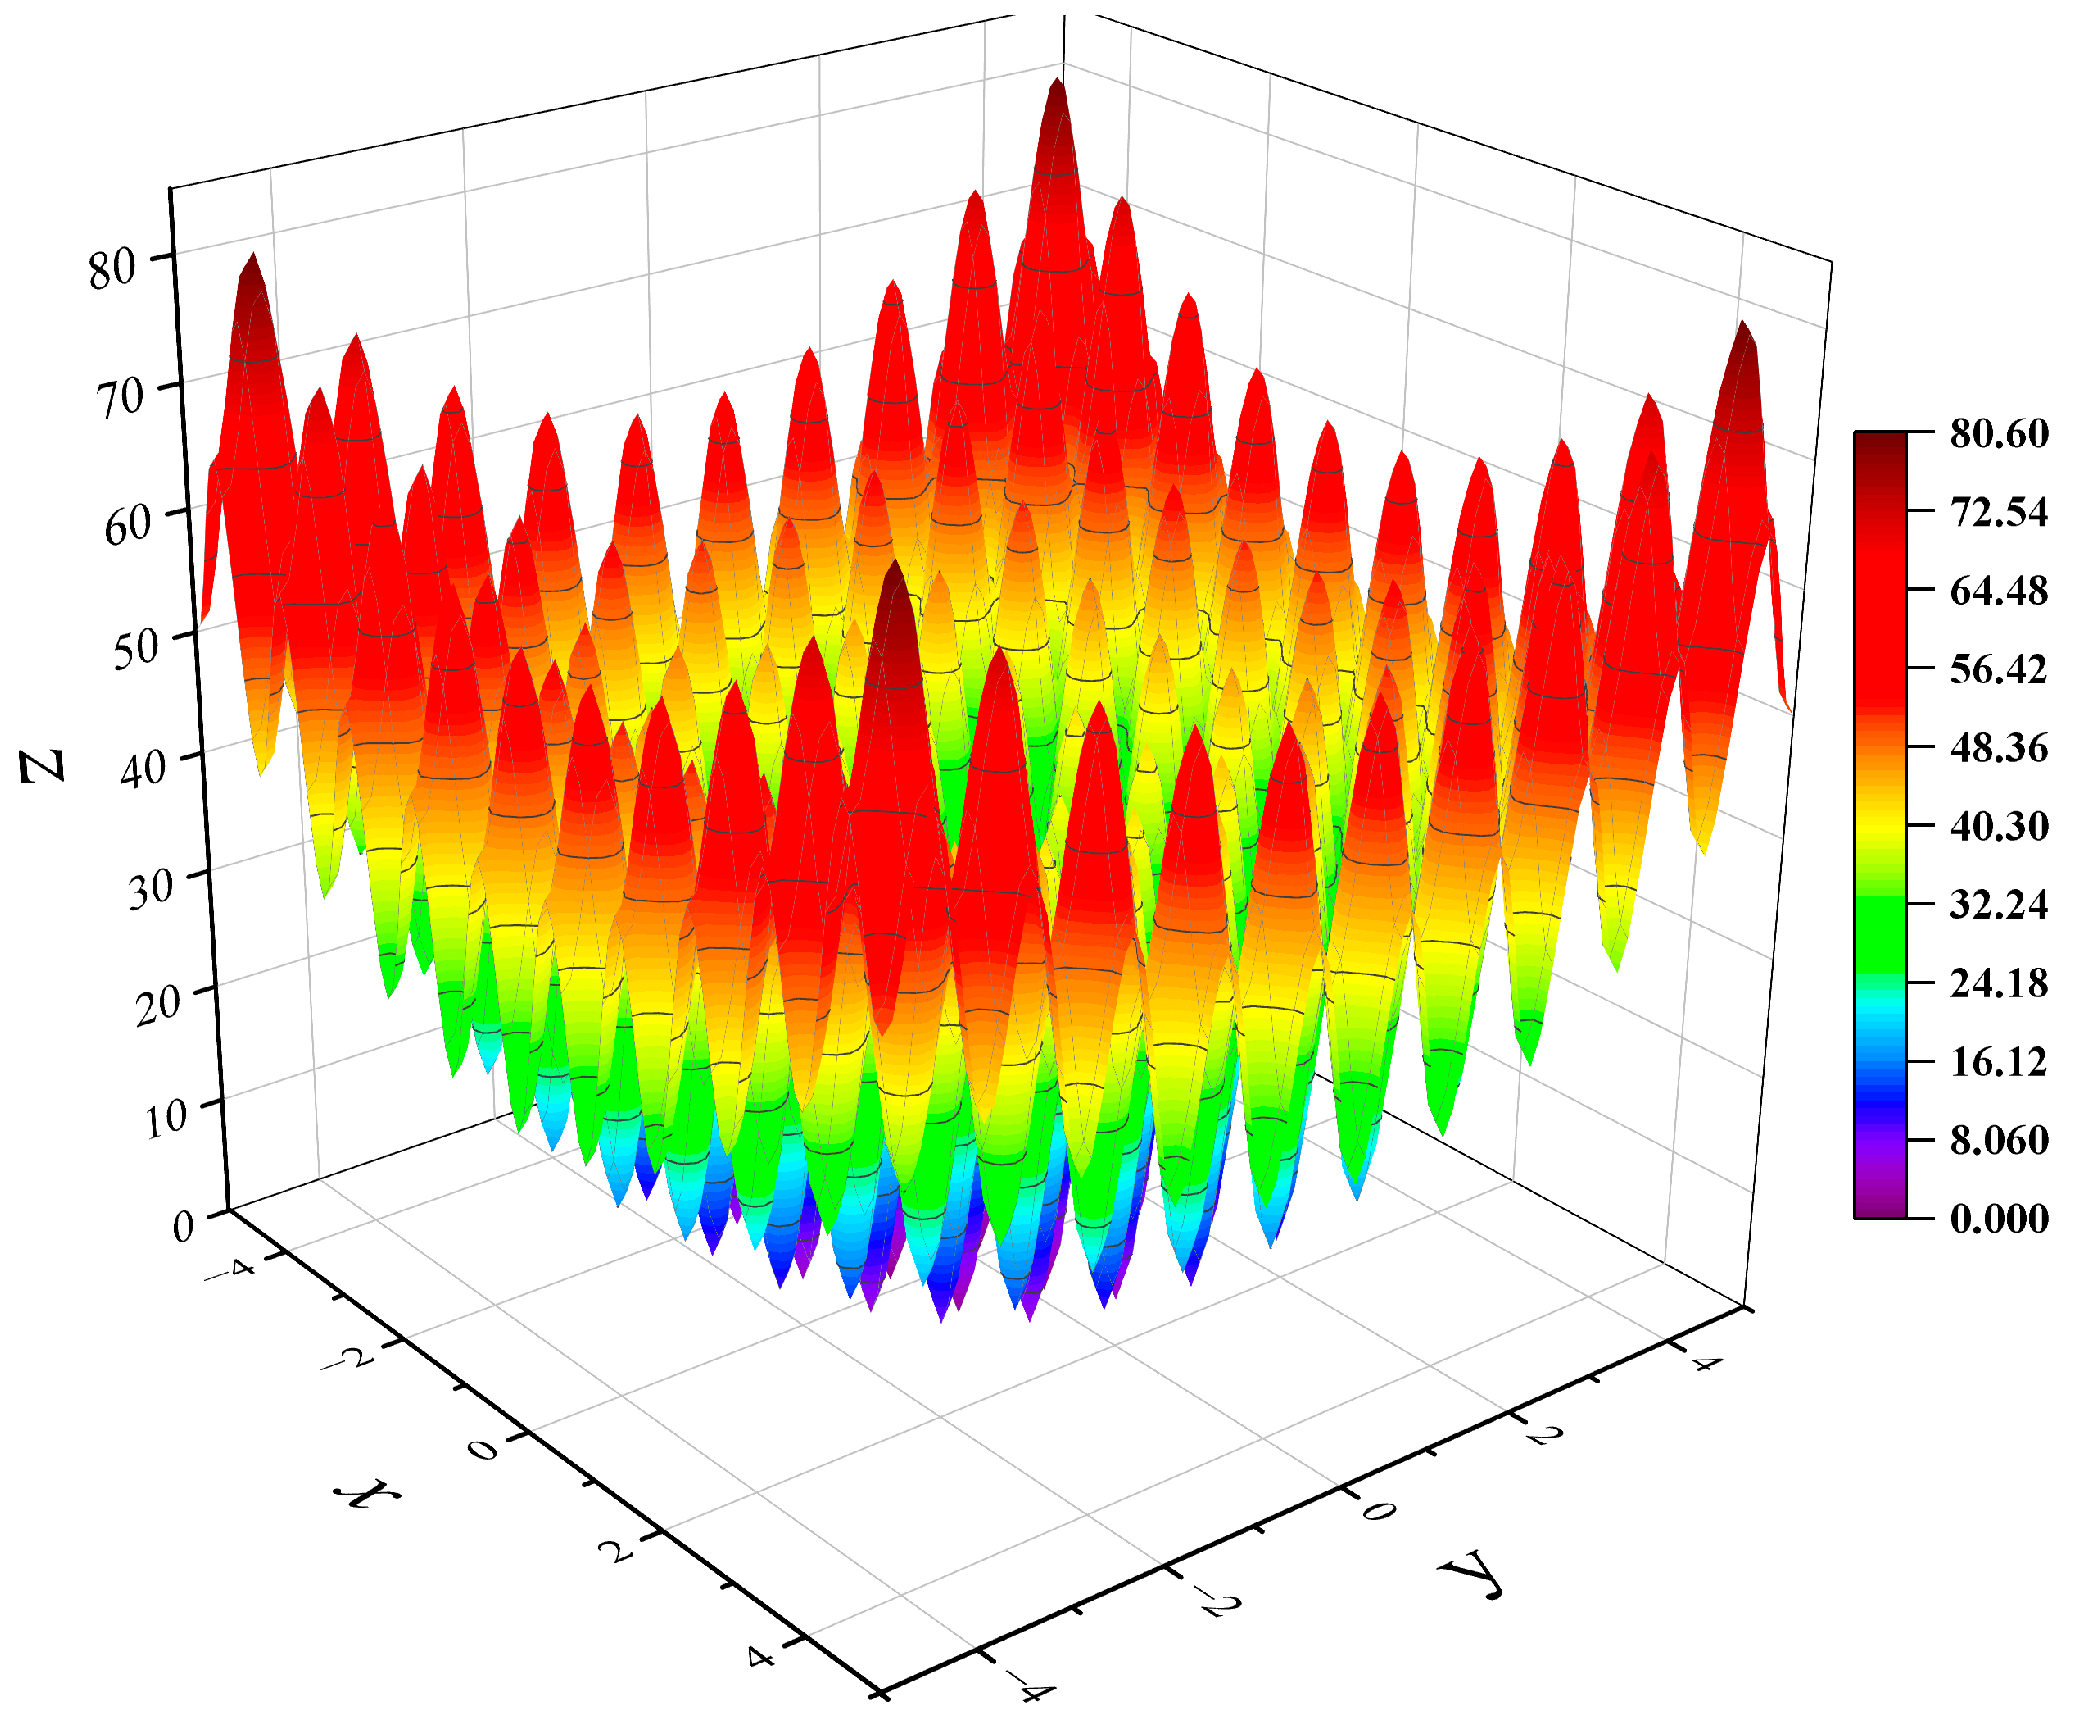
Validating the performance of a new algorithm typically requires an effective approach. For intelligent optimization algorithms, this often involves solving benchmark numerical problems to verify their performance. As shown in Figure 17, the Rastrigin function was used to compare the performance of the improved GA with the standard GA.
Figure 17.
Rastrigin function schematic.
Here, both algorithms had a population size of 100, and each population was iterated 100 times in a single experiment. The remaining parameters for the standard GA and the improved GA are shown in Table 2 and Table 3. In addition, Nm represents the number of offspring generated from the mutation operation and Nc represents the number of offspring generated from the crossover operation.
Table 2.
Parameters of improved GA.
Table 3.
Parameters of standard GA.
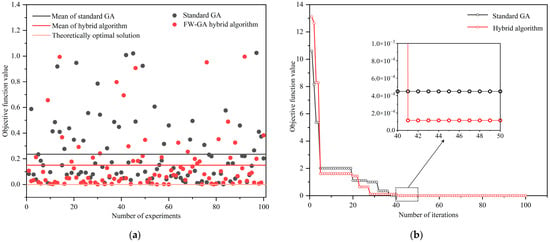
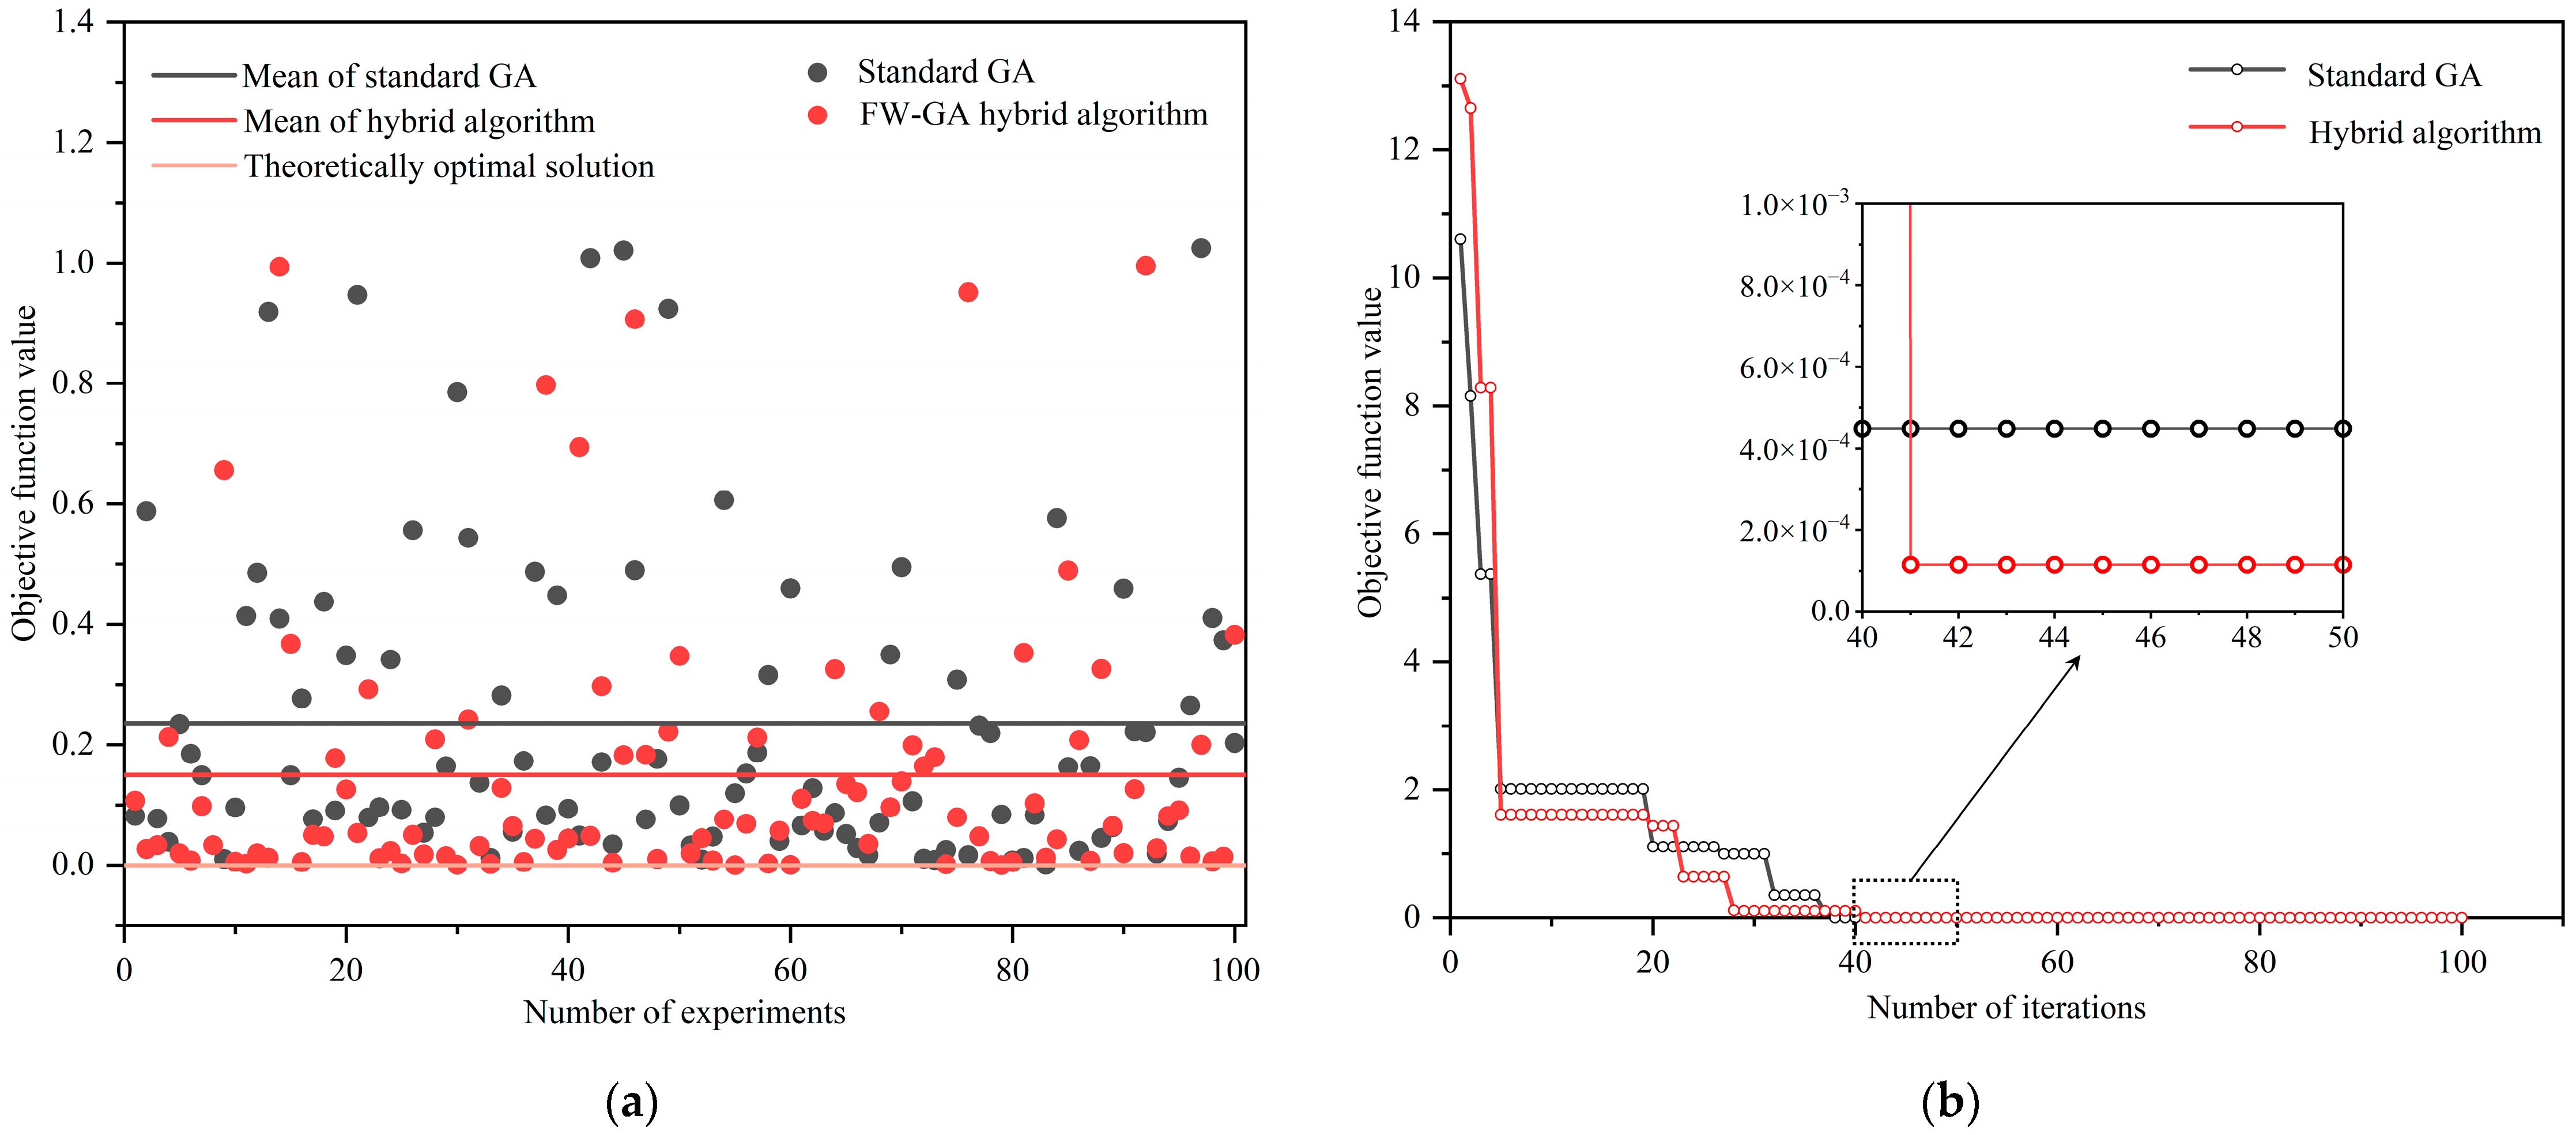
Based on both the standard GA and the improved GA, this study conducted 100 independent, repeated experiments and recorded the results of the objective function for each experiment. Figure 18a shows that the distribution of the improved GA’s results was closer to the theoretical optimal solution, and the mean of the improved GA’s results was smaller than that of the traditional GA. This improvement is due to the dynamic adjustment strategy of the improved genetic algorithm, which adjusts the probabilities of mutation, crossover, and the number of offspring based on the fitness of different individuals. This strategy allows the algorithm to balance both local and global optimization, resulting in better optimization results.
Figure 18.
Diagram of the solution results based on different algorithms. (a) Objective function value distribution; (b) objective function value curve.
The iteration process of the best solution is also shown in the Figure 18b. It is evident that the improved GA converges faster than the traditional GA, with slightly better optimization results. Furthermore, the improved GA had a running time of 5.683617 s, whereas the traditional GA had a running time of 7.183068 s. This demonstrates that the dynamic adjustment strategy of the improved GA makes it more efficient in the utilization of computing resources compared to the traditional GA.
Overall, the results demonstrate the advantages of the improved GA in terms of optimization performance and computational efficiency. The dynamic adjustment strategy of the improved algorithm allows for a more effective balance between local and global optimization, resulting in better optimization results. Additionally, the improved algorithm’s efficient utilization of computing resources makes it an attractive option for solving complex optimization problems.
4.2.2. Solve the MKP Problem Based on the Standard GA
In the previous section, the basic theory of the standard GA was introduced. This section explains how the standard GA was adopted to solve the MKP problem. The parameters of the standard GA are shown in Table 4. In addition, each independent repeated experiment consisted of 100 generations of iteration. Here, the first iteration convergence method was adopted, and the number of iterations is denoted as the iteration convergence times.
Table 4.
Parameters in GA.
The constraints of the MKP were set as the following:
- The sum of the Euclidean distances between the fire points and the initial position is no more than 10,000 km.
- There is a maximum of 130 fire points to be reconnoitered by each UAV.
- There is a maximum storage space of 50 for each UAV.
Table 5 presents the solution time, iteration number and objective function value of the standard GA for the MKP problem under different population sizes. It should be noted that the running time here refers to the total time for 50 independent, repeated experiments, whereas the iteration number refers to the average iteration number of the 50 independent repeated experiments. The experimental results show that as the population size increased, the running time increased significantly. This is because the increase in population size led to a significant increase in the computational workload, resulting in a significant increase in computer running time. In addition, the number of iterations and the objective function value were slightly improved due to the increase in the number of populations. This is because the increase in the number of populations increased the number of parents and offspring in each generation, thereby accelerating the iteration process and improving the fitness of the population. However, it should be pointed out that the increase in iteration speed does not mean a decrease in running time because with the increase in population size, the computational resource consumption of each generation increased significantly.
Table 5.
Parameters in GA.
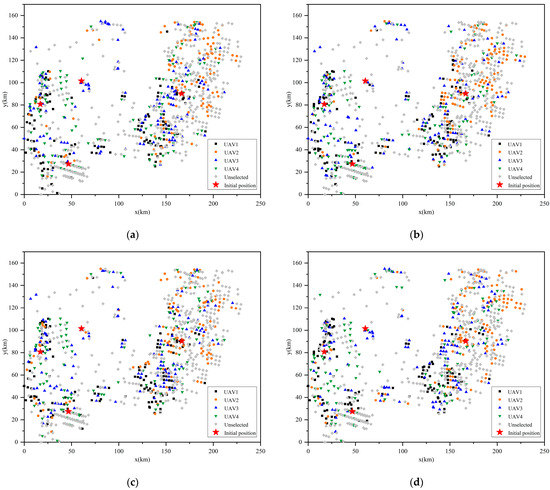
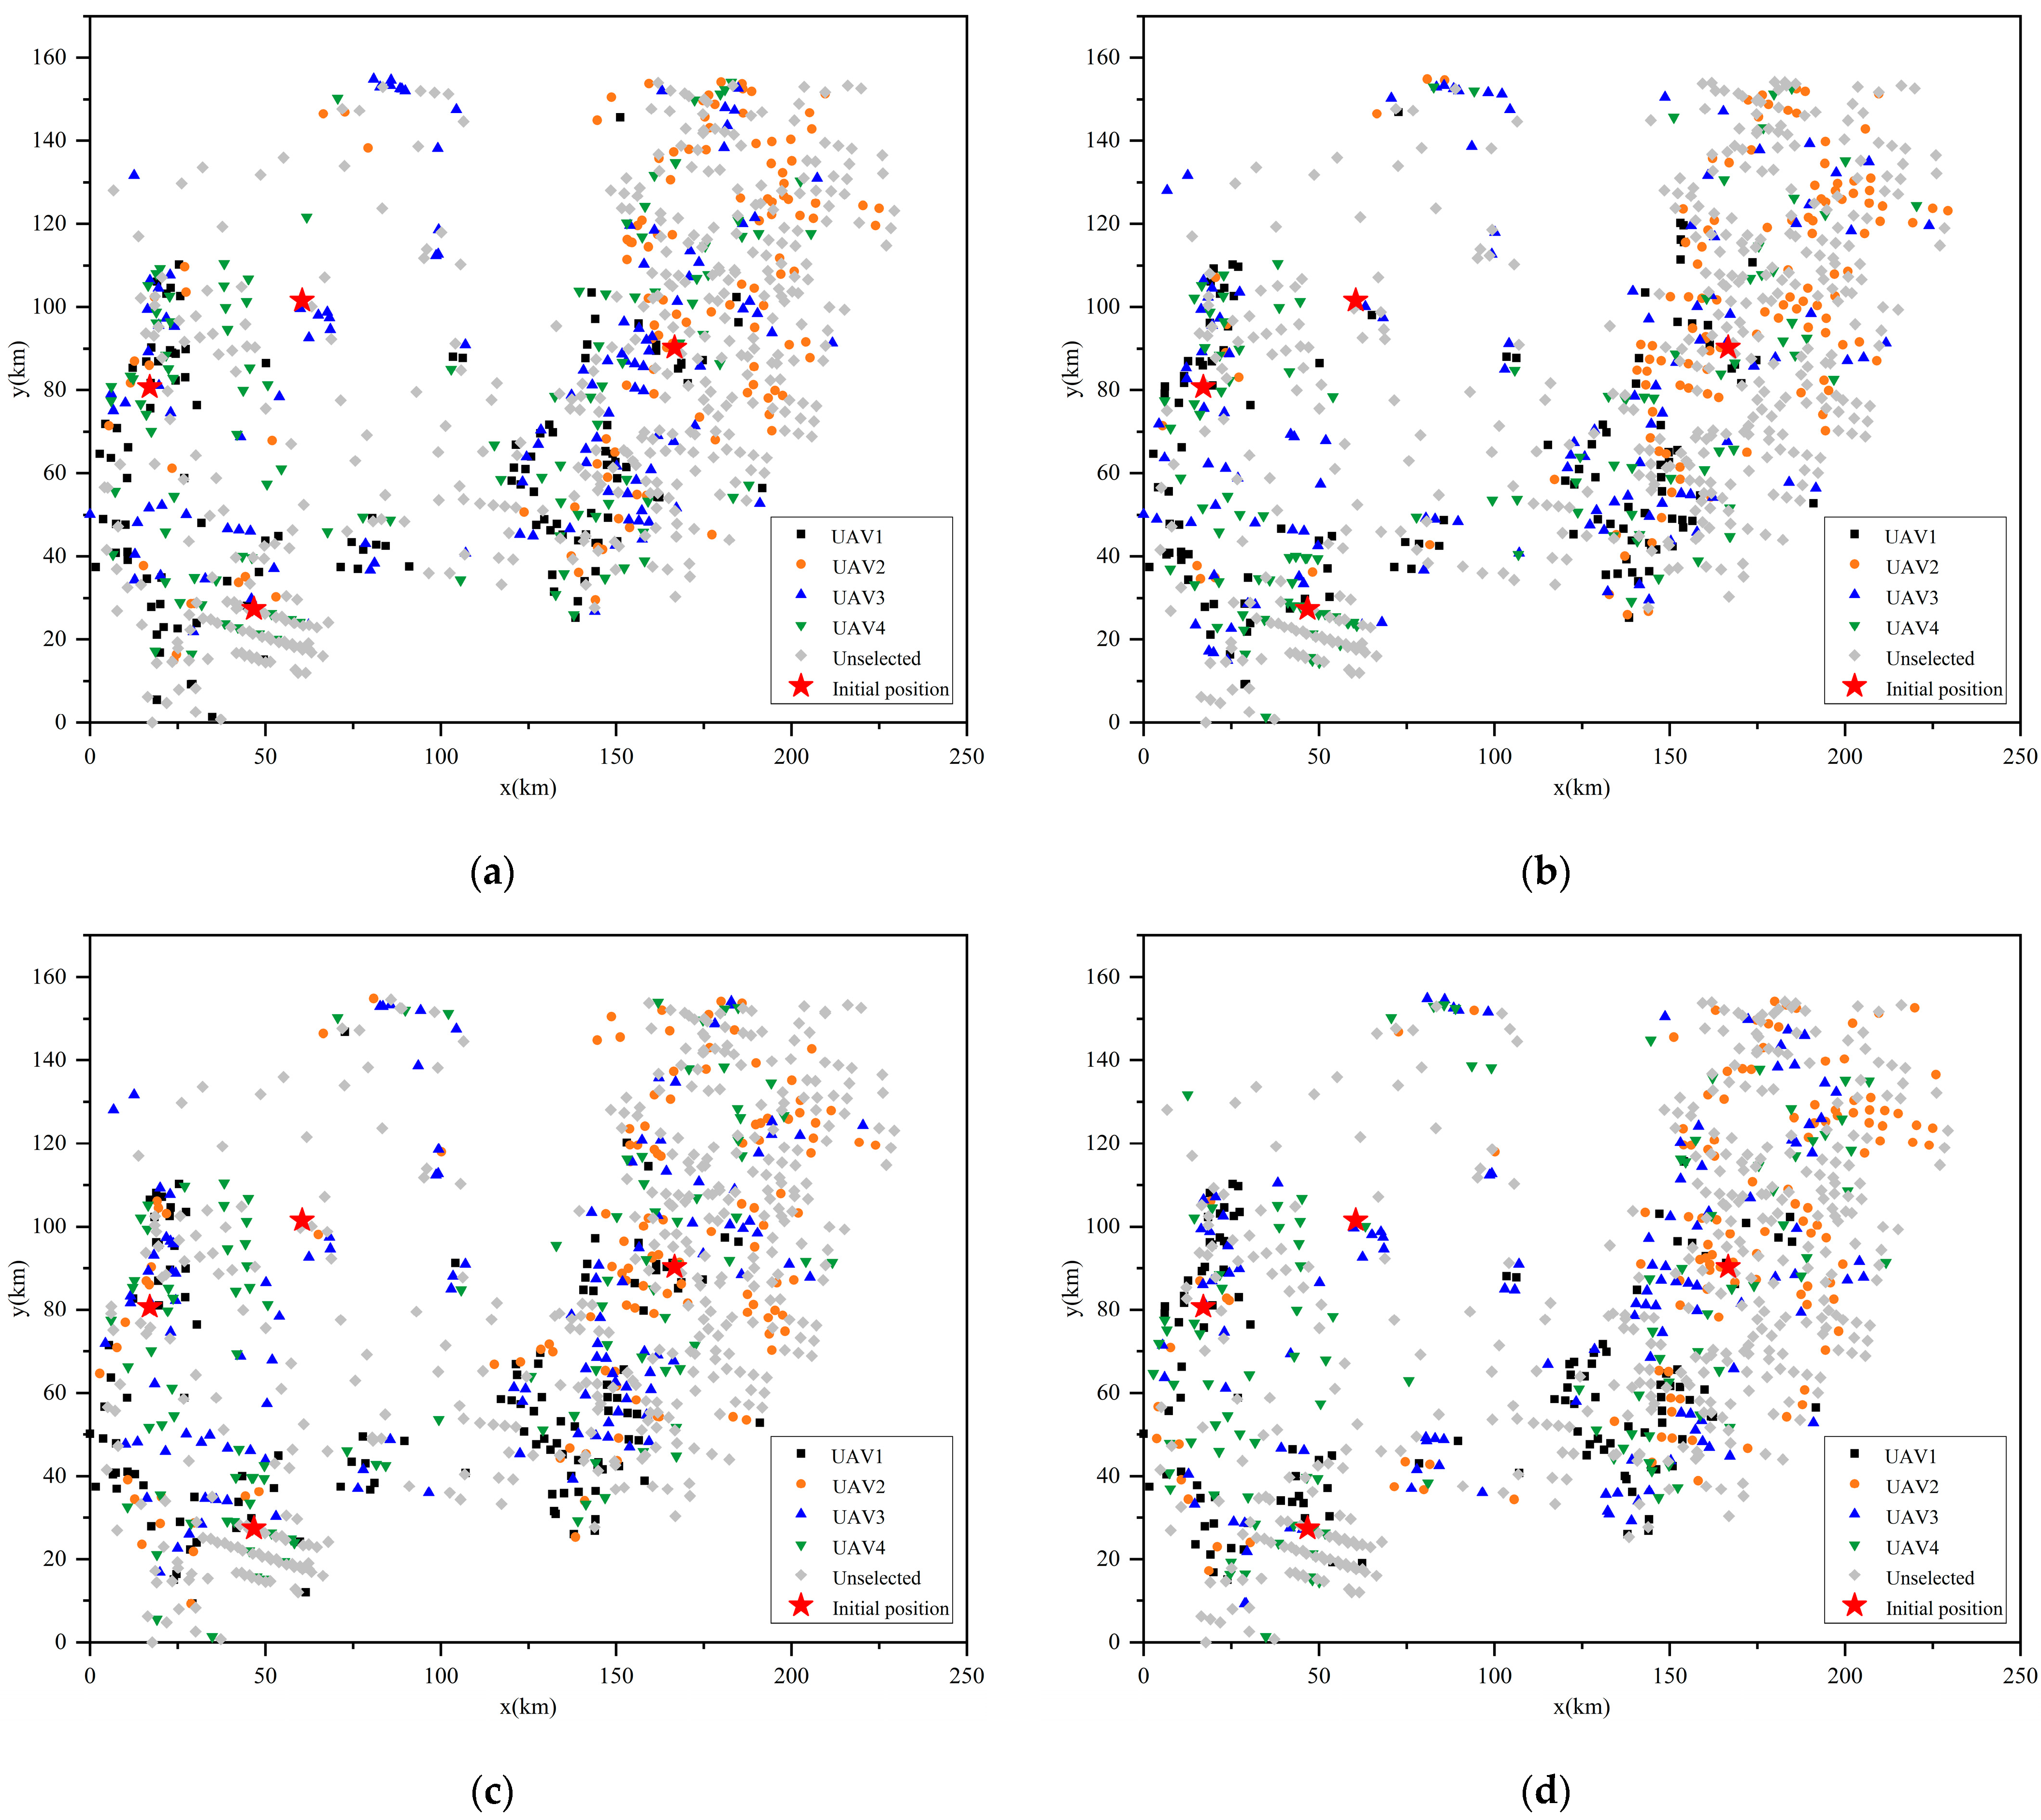
In Figure 19, it can be seen that the 1st and 2nd UAVs were assigned to more concentrated fire points, whereas the 3rd and 4th UAVs were assigned to more scattered fire points. Comparing the Gaussian mixture model and the ranks of the fire points, it can be seen that this is because the 1st and 2nd UAVs had more important fire points near initial positions. Therefore, more important fire points near their initial positions were assigned to the 1st and 2nd UAVs.
Figure 19.
Fire point allocation results. (a) Allocation results when N = 50; (b) allocation results when N = 100; (c) allocation results when N = 150; (d) allocation results when N = 200.
It is worth noting that its constraint condition is the sum of the fire points and the initial positions rather than the traditional models that strictly divide the fire points by region. Therefore, the 1st UAV could be assigned to fire points with high ranks near the initial positions of the 2nd and 3rd UAVs. As can be clearly seen in Figure 4 and Figure 19, there were many fire points with high ranks near the initial position of the 2nd UAV. If strictly dividing by position, it would be difficult for the 2nd UAV to execute its reconnaissance tasks quickly. For the 3rd UAV, because there were fewer fire points near its initial position, it could reach a longer distance without strict regional restrictions. Similarly, for the 4th UAV, because the first three UAVs had been assigned a large number of tasks and there were few remaining fire points near it, it could reach a longer distance like the 3rd UAV.
4.2.3. Solve the MKP Problem Based on the FW–GA Hybrid Algorithm
- The unbiased overall measurements justification
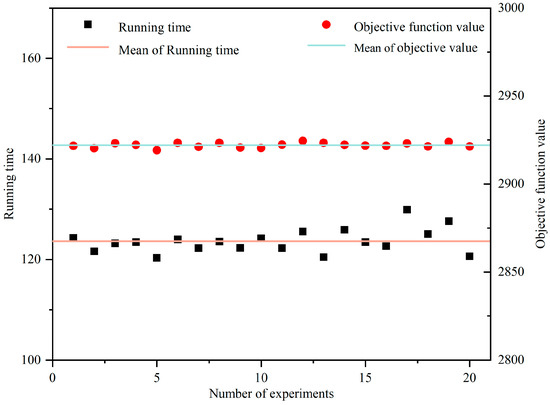
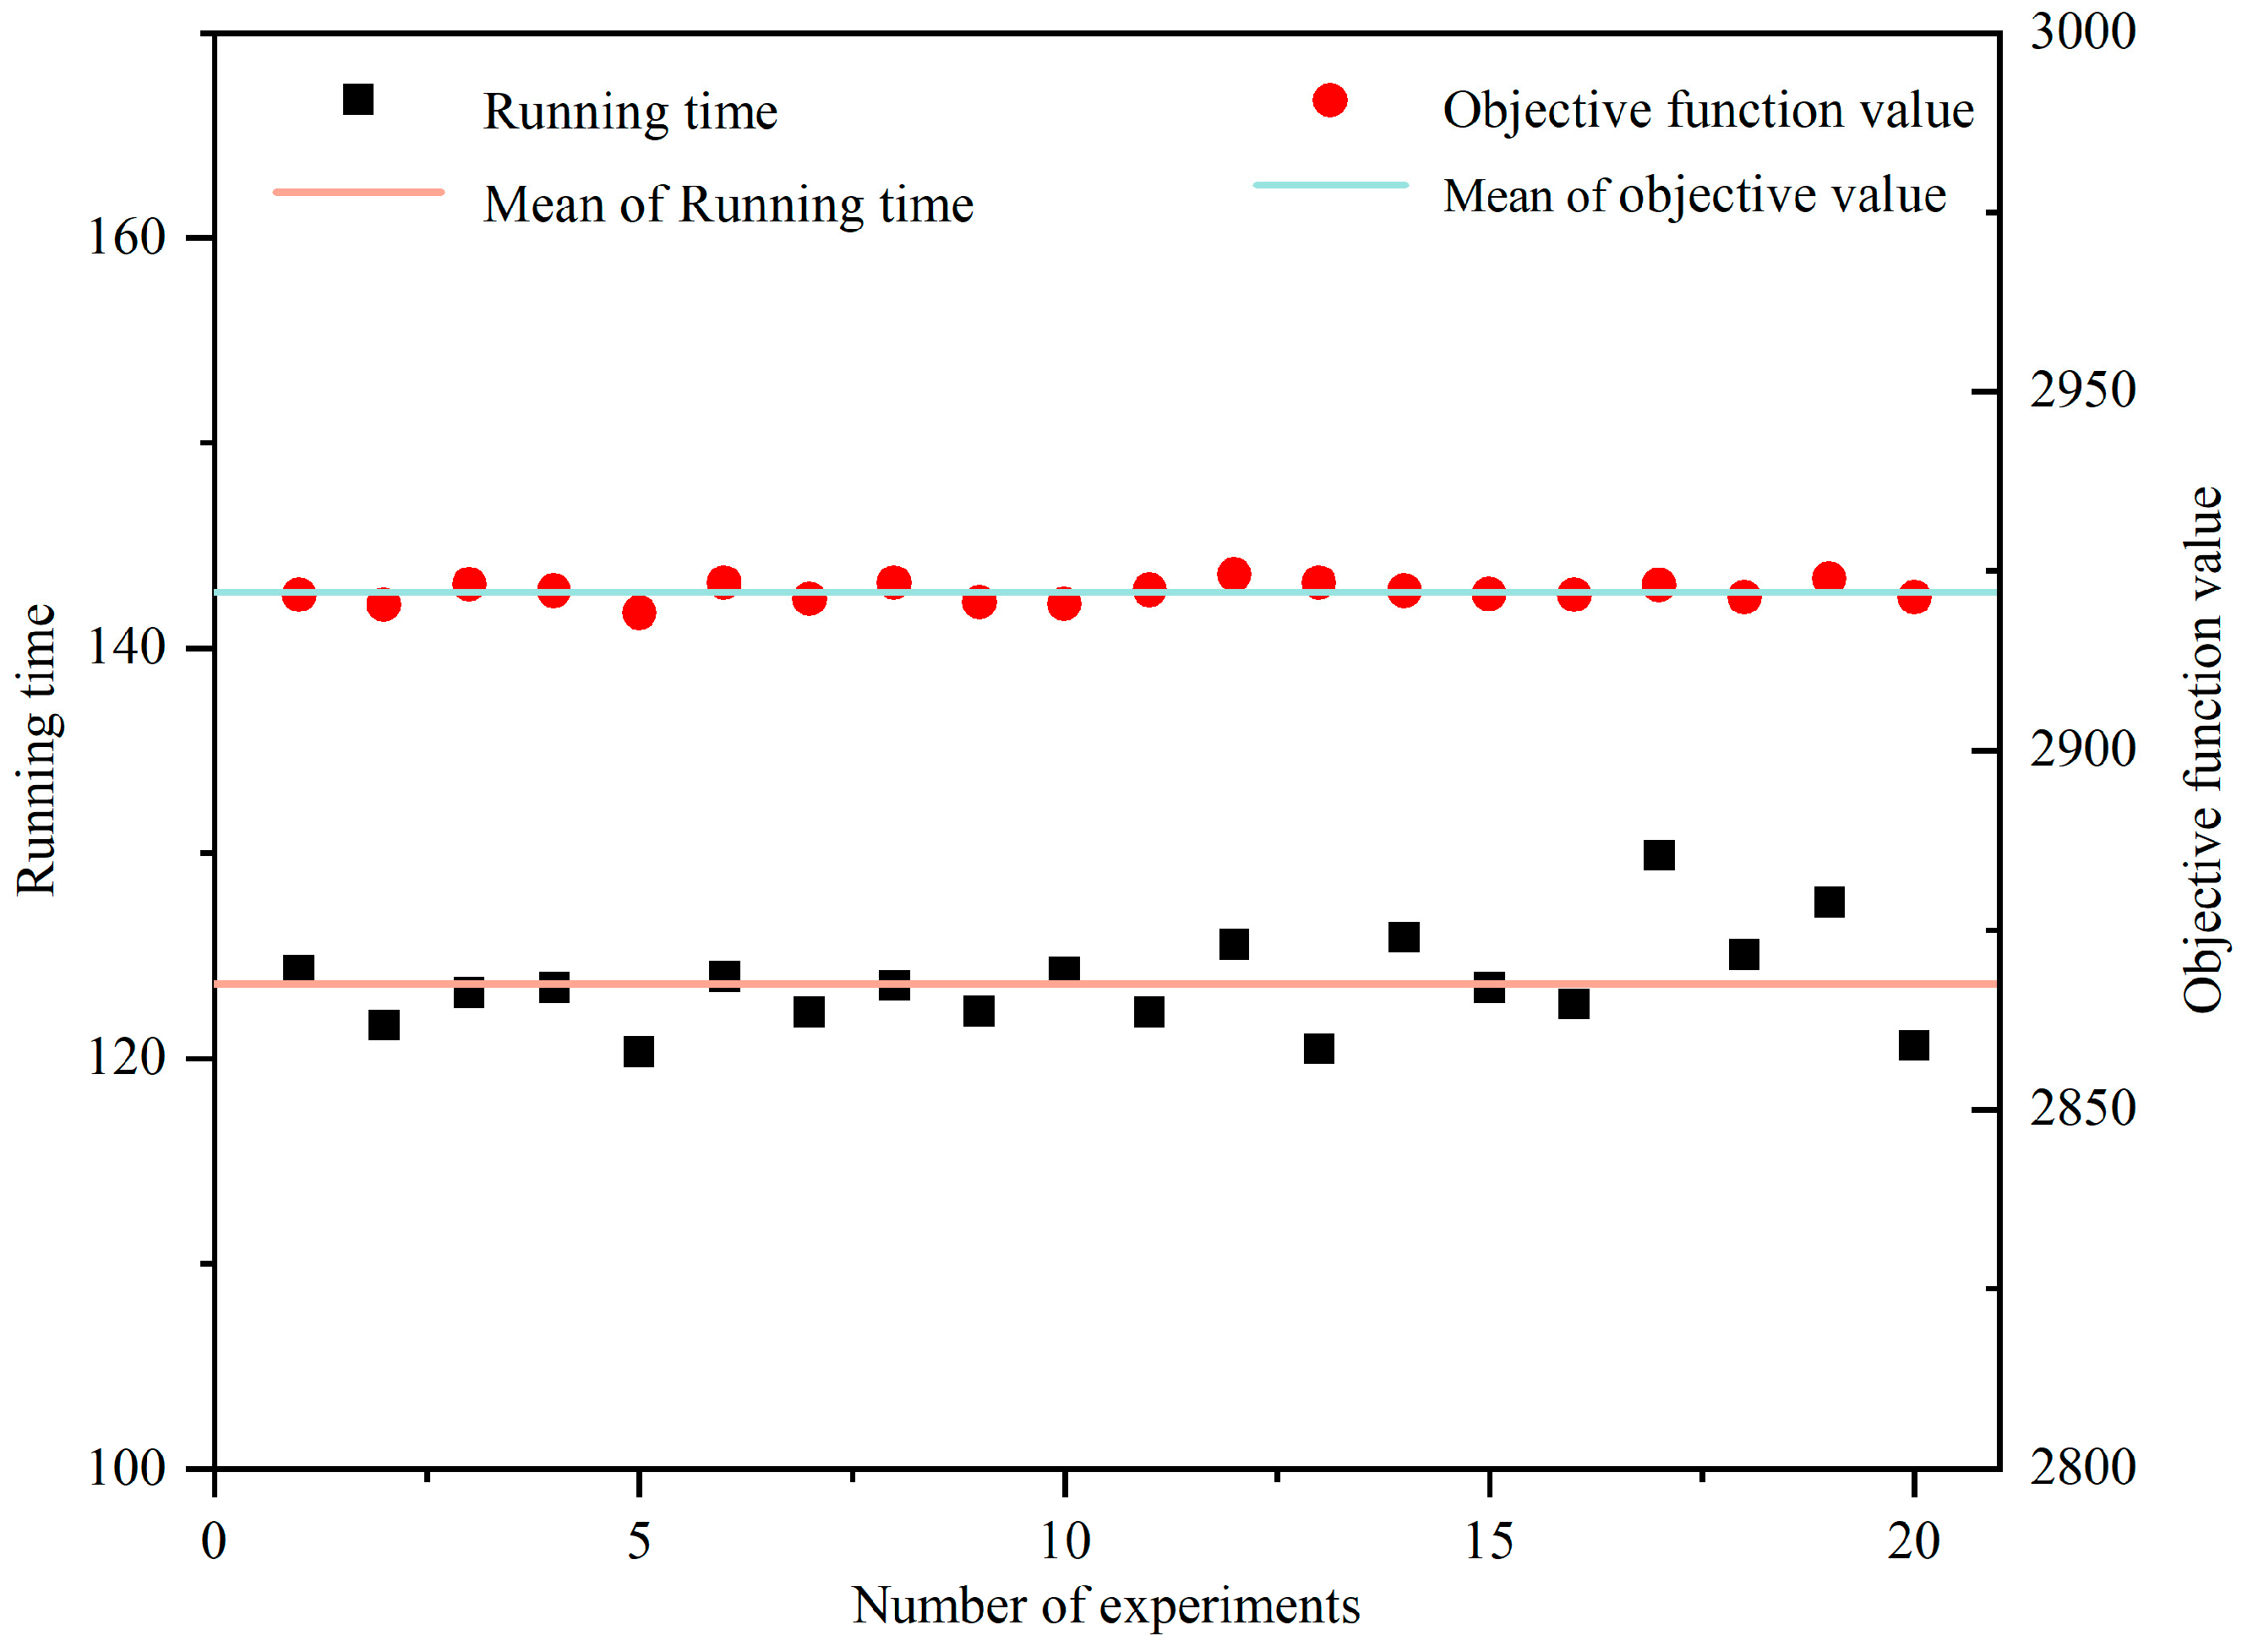
The solving process of intelligent optimization algorithms is typically characterized by a high degree of randomness, resulting in significant fluctuations in the obtained results. Although the proposed algorithm repeated the experiment 50 times to obtain the average, the unbiasedness of the measurement results requires further validation. To address this issue, the hybrid algorithm was employed to conduct 20 independent, repeated experiments, each involving 50 iterations, to record the time and average value of the objective function for each experiment. The experimental results of the 20 experiments are presented in Figure 20, which clearly shows that the fluctuation of the objective function among the 20 experiments was minimal, with the variation in the running time also being within a small range. Through statistical analysis, the variance of the objective function value for the 20 experiments was found to be 1.758475, and the variance of the running time was 5.392467, both of which are within an acceptable range.
Figure 20.
Results diagram of 20 independent, repeated experiments.
- 2.
- Solving the MKP problem
In complex forest fires, time is of the essence. According to the simulation results in Section 4.2.2, it was found that the standard GA has a relatively slow solution speed and convergence speed. Therefore, it is necessary to improve the standard GA to make it more suitable for scenarios with higher requirements for solution speed and convergence speed, such as forest fires.
As mentioned earlier, the improved GA produces a dynamic number of population individuals with a dynamic mutation rate, which can theoretically accelerate the iteration speed of the algorithm. In order to further accelerate the iteration speed of the algorithm and avoid getting stuck in local optimal solutions, greedy selection and elite opposition-based learning mechanisms were introduced separately for simulation experiments. To analyze the advantages of the improved GA, four sets of experiments were conducted. As shown in Table 6, the first set of experiments solved the MKP problem based on the improved GA, the second set of experiments introduced the greedy selection algorithm on the basis of the improved GA, the third set of experiments introduced the elite opposition-based learning strategy on the basis of the improved GA and the fourth set of experiments simultaneously introduced the greedy algorithm and elite opposition-based learning.
Table 6.
Algorithms adopted for different experiments.
Similar to the experiment in the first section, each experiment was repeated 50 times to avoid the impact of the randomness of the intelligent optimization algorithm on the iterative optimization. The running time and the average number of iterations and average objective value were defined the same as in Section 4.2.2. The population size of the improved GA was set to be the same as in Section 4.2.2. The iteration convergence condition was the same as that of the traditional GA. For the mutation and crossover operators, the parameter settings are shown in Table 7, and the meanings of the parameters , , and are as defined earlier.
Table 7.
Simulation parameters.
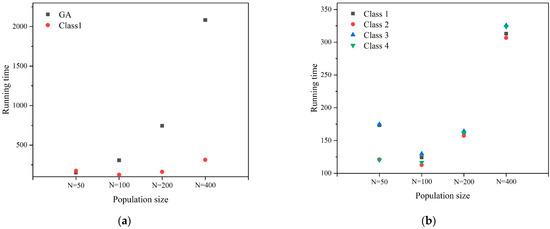
Figure 21a presents a comparison of the running time between the traditional GA and the improved GA under varying population sizes. It is evident that, for the traditional GA, an increase in population size resulted in a significant rise in computational cost, leading to a substantial increase in running time. Conversely, for the improved GA, the running time only increased with population size when it exceeded 100. However, when the population size was 50, the running time was greater than when the population size was 100. This is because the traditional GA is prone to being trapped in local optima when the population size is small, causing early convergence and thereby occupying an advantage in solution time. In contrast, the improved GA possesses a certain capability to globally optimize the objective function, avoiding premature convergence in local optima and resulting in better objective function values than the traditional GA.
Figure 21.
Comparison of the running times for different population sizes. (a) Comparison between GA and class1; (b) comparison between different experiment classes.
The simulation results also show that when the population size was greater than 100, the running time of the improved GA was much lower than the standard GA, and the greater the population size, the more obvious the difference became. Table 8 shows the specific data of the GA and the improved GA. It can be seen that when the population size was 400, the running time of the improved GA had even reduced by 566%. This is due to the fact that, in the standard GA, doubling the population size results in an exponential increase in required computational resources. However, for the improved GA, the dynamic allocation of computational resources can significantly enhance the utilization of computational resources. Furthermore, the advantage of dynamic allocation became more apparent as the population size increased.
Table 8.
Comparison of the number of iterations between the standard GA and modified GA.
Figure 21b illustrates a comparison of the running time among different experimental classes with varying population sizes. The results clearly demonstrate that the introduction of a greedy selection operator can effectively reduce the algorithm’s solving time. Notably, when the population size was small, the greedy selection operator expedited the algorithm’s convergence towards a near-optimal solution, thereby accelerating iteration and substantially decreasing the algorithm’s solving time.
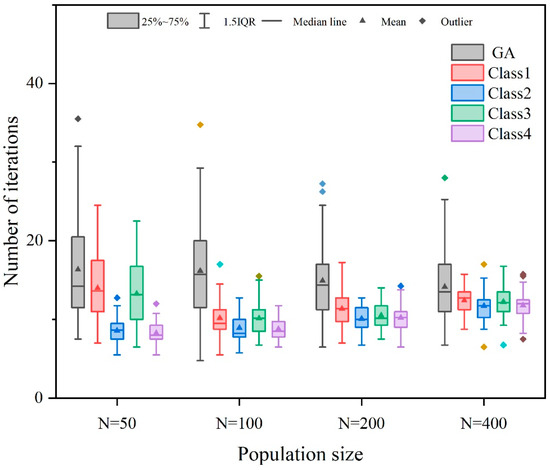
In Figure 22, a comparison of the iteration numbers among different population sizes clearly demonstrates that the improved GA requires fewer iterations compared to the standard GA. This is due to the improved GA’s dynamic adjustment capabilities during the iteration process, which enable it to conduct directed iteration for optimization, resulting in a faster iteration speed than the standard GA. Moreover, Figure 22 indicates that introducing the greedy selection operator reduced iteration numbers and ensured more stable iterations. However, the elite reverse learning strategy did not significantly enhance iteration speed.
Figure 22.
Comparison of the number of iterations for different population sizes.
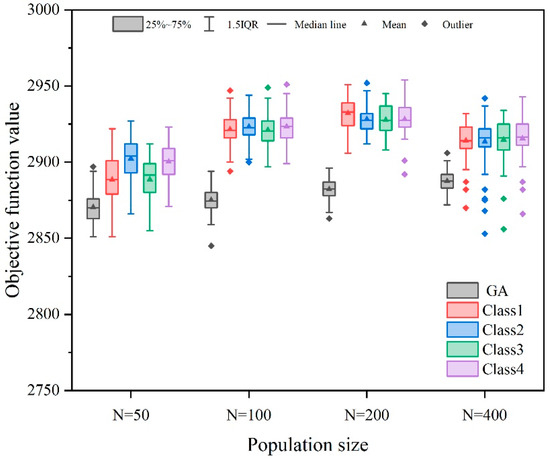
Figure 23 compares the objective function values among different population sizes, and it is observed that the improved GA achieved superior optimization results compared to the standard GA, with an average improvement of 1.7% in the objective function’s value. This is attributed to the hybrid algorithm’s more directed iteration process, which enhances the likelihood of finding better solutions. Moreover, as the population size increased, the objective function value of the standard GA slightly improved due to the increased number of solutions generated each iteration, leading to a higher probability of discovering better solutions. Nevertheless, for the improved GA, when the population size surpassed 100, the best solution obtained fluctuated within a small range, and the difference is not statistically significant. This is because the best solution obtained by the algorithm was already close to the optimal solution; thus, it fluctuated within a certain range. Additionally, Figure 23 suggests that the standard GA exhibited superior stability in different population sizes compared to the FW–GA hybrid algorithm.
Figure 23.
Comparison of the objective function for different population sizes.
In light of the results presented in Figure 23, it can be inferred that the greedy selection operator significantly enhanced the objective function’s value when the population size was small, but the elite reverse learning strategy did not significantly improve the best solution obtained by the algorithm. However, when the population size was large, neither the greedy selection operator nor the elite reverse learning strategy provided notable improvements in the objective function’s value.
To further verify the advantages of the proposed algorithm in terms of solution speed and effectiveness, experiments were conducted on solving the UAV task assignment model using the algorithm proposed in the literature [12], and the results were compared in terms of solution time and objective function value. The GA–SA algorithm was applied to solve the UAV task assignment model with two population sizes of 20 and 50, where the former is the population size set in the literature, and the other algorithm parameters were set according to the literature. The simulation results presented in Table 9 demonstrate that the proposed hybrid algorithm outperformed the GA–SA algorithm in terms of both objective function value and running time. Specifically, under the same population size, the running time of the hybrid algorithm was approximately 60 times shorter, and the objective function value improved by 1.3%.
Table 9.
Comparison of performance between FW–GA and GA–SA.
5. Conclusions
In this paper, a two-phase centralized UAV task assignment model for forest fire reconnaissance is established. In the preprocessing phase, a digital model of real forest fire is established based on information from satellite-borne sensors. Then, the initial position of each UAV is obtained with the EM algorithm based on GMM. In the UAV mission planning phase, a FW–GA hybrid algorithm is proposed to solve the MKP problem to improve the convergence speed of the standard GA. Finally, simulation experiments were conducted with the background of the 2020 Liangshan wildfire to verify the effectiveness of the model and the effectiveness of the hybrid algorithm. The simulation results indicate that the proposed algorithm can rapidly and efficiently solve the UAV task assignment model, resulting in faster solution speed, efficient utilization of computing resources and superior optimization results compared to the standard GA. In the future, we will focus on introducing reconnaissance strategies into real systems and verifying the effectiveness of reconnaissance model through real UAVs.
Author Contributions
All authors contributed to the study’s conception and design. Material preparation and data collection were performed by X.L. and L.H. Data analysis and method design were performed by X.L. and T.J. The first draft of the manuscript was written by X.L., T.J. and L.H. read the first draft and gave some modification suggestions. All authors have read and agreed to the published version of the manuscript.
Funding
The work was supported by the National Natural Science Foundation of China under Grants (72101263). Project title: Research on Markovian stochastic dynamic programming for large-scale unmanned swarm information collection.
Institutional Review Board Statement
Not applicable.
Informed Consent Statement
Not applicable.
Data Availability Statement
All data in this study will be available on reasonable request.
Conflicts of Interest
The authors have no relevant financial or non-financial interest to disclose.
References
- Li, J.T.; Zhang, S.; Zheng, Z.; Xing, L.N.; He, R.J. Research on Multi-UAV Loading Multi-Type Sensors Cooperative Reconnaissance Task Planning Based on Genetic Algorithm. Lect. Notes Comput. Sci. 2017, 10361, 485–500. [Google Scholar] [CrossRef] [Scilit]
- Sun, C.H.; Wang, X.C.; Qiu, H.X.; Zhou, Q.R. Game Theoretic Self-Organization in Multi-Satellite Distributed Task Allocation. Aerosp. Sci. Technol. 2021, 112, 106650. [Google Scholar] [CrossRef] [Scilit]
- Draganjac, I.; Miklic, D.; Kovacic, Z.; Vasiljevic, G.; Bogdan, S. Decentralized Control of Multi-AGV Systems in Autonomous Warehousing Applications. IEEE Trans. Autom. Sci. Eng. 2016, 4, 1433–1447. [Google Scholar] [CrossRef] [Scilit]
- Ryck, M.D.; Pissoort, D.; Holvoet, T.; Demeester, E. Decentral Task Allocation for Industrial AGV-Systems with Resource Constraints. J. Manuf. Syst. 2021, 59, 310–319. [Google Scholar] [CrossRef] [Scilit]
- Duan, X.J.; Duan, X.J.; Liu, H.Y.; Tang, H.; Cai, X.; Zhang, F.; Han, X.T. A Novel Hybrid Auction Algorithm for Multi-UAVs Dynamic Task Assignment. IEEE Access 2020, 8, 86207–86222. [Google Scholar] [CrossRef] [Scilit]
- Eun, Y.; Bang, H. Cooperative Task Assignment/Path Planning of Multiple Unmanned Aerial Vehicles Using Genetic Algorithm. J. Aircr. 2009, 1, 338–343. [Google Scholar] [CrossRef] [Scilit]
- Zhang, J.R.; Wang, G.; Song, Y.F. Task Assignment of the Improved Contract Net Protocol under a Multi-Agent System. Algorithms 2019, 12, 70. [Google Scholar] [CrossRef] [Scilit]
- Smith, R.G. The Contract Net Protocol: High-Level Communication and Control in a Distributed Problem Solver. IEEE Trans. Comput. 1980, 12, 1104–1113. [Google Scholar] [CrossRef] [Scilit]
- Yao, P.; Wang, H.L.; Ji, H.X. Gaussian Mixture Model and Receding Horizon Control for Multiple UAV Search in Complex Environment. Nonlinear Dyn. 2017, 88, 903–919. [Google Scholar] [CrossRef] [Scilit]
- Muhuri, P.K.; Rauniyar, A. Immigrants Based Adaptive Genetic Algorithms for Task Allocation in Multi-Robot Systems. Int. J. Comput. Intell. Appl. 2017, 16, 1750025. [Google Scholar] [CrossRef] [Scilit]
- Jena, T.; Mohanty, J.R. GA-Based Customer-Conscious Resource Allocation and Task Scheduling in Multi-Cloud Computing. Arab. J. Sci. Eng. 2018, 43, 4115–4130. [Google Scholar] [CrossRef] [Scilit]
- Long, X.Y.; Wu, S.F.; Wu, X.F.; Huang, Y.X.; Mu, Z.C. A GA-SA Hybrid Planning Algorithm Combined with Improved Clustering for LEO Observation Satellite Missions. Algorithms 2019, 12, 231. [Google Scholar] [CrossRef] [Scilit]
- Zhang, X.P.; Chen, X.J. UAV Task Allocation Based on Clone Selection Algorithm. Wirel. Commun. Mob. Comput. 2021, 2021, 5518927. [Google Scholar] [CrossRef] [Scilit]
- Xu, Y.; Sun, Z.; Xue, X.Y.; Gu, W.; Peng, B. A Hybrid Algorithm Based on MOSFLA and GA for Multi-UAVs Plant Protection Task Assignment and Sequencing Optimization. Appl. Soft Comput. 2020, 96, 106623. [Google Scholar] [CrossRef] [Scilit]
- Kim, J.; Oh, H.; Yu, B.; Kim, S. Optimal Task Assignment for UAV Swarm Operations in Hostile Environments. Int. J. Aeronaut. Space Sci. 2020, 22, 456–467. [Google Scholar] [CrossRef] [Scilit]
- Manathara, J.G.; Sujit, P.B.; Beard, R.W. Multiple UAV Coalitions for a Search and Prosecute Mission. J. Intell. Robot. Syst. 2011, 62, 125–158. [Google Scholar] [CrossRef] [Scilit]
- Chen, X.; Liu, Y.T.; Qi, L.J. Cooperative Task Assignment and Track Planning For Multi-UAV Attack Mobile Targets. J. Intell. Robot. Syst. 2020, 100, 1383–1400. [Google Scholar] [CrossRef] [Scilit]
- Yan, F.L. Gauss Interference Ant Colony Algorithm-Based Optimization of UAV Mission Planning. J. Supercomput. 2020, 76, 1170–1179. [Google Scholar] [CrossRef] [Scilit]
- Li, J.Z.; Tan, Y. A Comprehensive Review of the Fireworks Algorithm. ACM Comput. Surv. 2020, 52, 121. [Google Scholar] [CrossRef] [Scilit]
- Wei, W.Q.; Ouyang, H.B.; Zhang, C.L.; Li, S.; Fu, L.Y.; Gao, L.Q. Dynamic Collaborative Fireworks Algorithm and Its Applications in Robust Pole Assignment Optimization. Appl. Soft Comput. 2020, 100, 106999. [Google Scholar] [CrossRef] [Scilit]
- Ehsan, E.; Alireza, Z. FOA: Fireworks Optimization Algorithm. Multimedia Tools Appl. 2022, 81, 33151–33170. [Google Scholar] [CrossRef] [Scilit]
- Tan, Y.; Zhu, Y.C. Fireworks Algorithm for Optimization. Lect. Notes Comput. Sci. 2010, 6145, 355–364. [Google Scholar] [CrossRef] [Scilit]
- Mnif, M.; Bouamama, S. Firework Algorithm For Multi-Objective Optimization Of A Multimodal Transportation Network Problem. Procedia Comput. Sci. 2017, 112, 1670–1682. [Google Scholar] [CrossRef] [Scilit]
- Ali, W.M.; Liu, J.C.; Ejaz, W. Planning Capacity for 5G and beyond Wireless Networks by Discrete Fireworks Algorithm with Ensemble of Local Search Methods. EURASIP J. Wirel. Commun. Netw. 2020, 2020, 185. [Google Scholar] [CrossRef] [Scilit]
- Horbulin, V.P.; Hulianytskyi, L.F.; Horbulin, V.P.; Sergienko, I.V. Optimization of UAV Team Routes in the Presence of Alternative and Dynamic Depots. Cybern. Syst. Anal. 2020, 56, 195–203. [Google Scholar] [CrossRef] [Scilit]
- Alan, R.; McKendall, J. Improved Tabu Search Heuristics for the Dynamic Space Allocation Problem. Comput. Oper. Res. 2008, 35, 3347–3359. [Google Scholar] [CrossRef] [Scilit]
- Niu, X.F.; Shen, L.C.; Ji, X.T. Robust Satisficing Decision Making for Unmanned Aerial Vehicle Complex Missions under Severe Uncertainty. PLoS ONE 2016, 11, e0166448. [Google Scholar] [CrossRef] [Scilit]
- Kuru, K.; Ansell, D.; Khan, W.; Yetgin, H. Analysis and Optimization of Unmanned Aerial Vehicle Swarms in Logistics: An Intelligent Delivery Platform. IEEE Access 2019, 7, 15804–15831. [Google Scholar] [CrossRef] [Scilit]
- Nina, S.; Juan, J.R.G.; Pau, F.; José, L.M.G. A Constraint Programming Model with Time Uncertainty for Cooperative Flight Departures. Transport. Res. C-Emerg. Technol. 2018, 96, 170–191. [Google Scholar] [CrossRef] [Scilit]
- Oussama, M.A.; Filip, V.U.; Marie-Anne, G. Military Human Resource Planning through Flow Network Modeling. Eng. Manag. J. 2021, 34, 302–313. [Google Scholar] [CrossRef] [Scilit]
- Chu, P.C. A Genetic Algorithm for the Multidimensional Knapsack Problem. J. Heurist. 1998, 6, 63–86. [Google Scholar] [CrossRef] [Scilit]
- Hao, J.K.; Barichard, V. Genetic Tabu Search for the Multi-Objective Knapsack Problem. Tsinghua Sci. Technol. 2003, 8, 8–13. [Google Scholar]
- Luis Fernando, M.L.; Nuria, G.B.; Alberto, A.A. Multidimensional Knapsack Problem Optimization Using a Binary Particle Swarm Model with Genetic Operations. Soft Comput. 2018, 22, 2567–2582. [Google Scholar] [CrossRef] [Scilit]

Disclaimer/Publisher’s Note: The statements, opinions and data contained in all publications are solely those of the individual author(s) and contributor(s) and not of MDPI and/or the editor(s). MDPI and/or the editor(s) disclaim responsibility for any injury to people or property resulting from any ideas, methods, instructions or products referred to in the content. |
© 2023 by the authors. Licensee MDPI, Basel, Switzerland. This article is an open access article distributed under the terms and conditions of the Creative Commons Attribution (CC BY) license (https://creativecommons.org/licenses/by/4.0/).