1. Introduction
Maintaining health and mobility in dogs—whether working animals or companion pets—has gained increasing attention in recent decades [
1,
2,
3]. This growing focus includes the development and implementation of physiotherapeutic programs aimed at enhancing musculoskeletal function and overall quality of life. These programs typically target core stability, strength, flexibility, and proprioception [
4,
5]. Active movement therapy in dogs may include exercises such as gait transitions, uphill or backward walking, obstacle courses, hydrotherapy, and walking or standing on variable surfaces, including soft mats. The goals of these exercises are to improve muscular elasticity and contractility, enhance proprioceptive input, increase soft tissue perfusion, promote balance and coordination, support joint and bone health, and maintain or restore functional movement patterns [
4,
6].
In veterinary medicine, the use of pressure plates to measure vertical ground reaction forces (vGRFs) has become increasingly prevalent over recent decades, offering an objective and noninvasive method to assess limb-ground interactions during the stance phase. VGRF analysis has been used to characterize normal gait patterns in healthy animals [
7,
8,
9], as an objective diagnostic tool for lameness [
10,
11,
12], and to evaluate the effects of various treatments [
13,
14]. Commonly derived parameters include peak vertical force (PFz), which represents the maximum vertical force exerted; vertical impulse (IFz), which reflects the total load over time; and time to PFz (TPFz), indicating the timing of peak force within the stance phase [
15,
16,
17].
In contrast to the well-established use of kinematics and electromyography in evaluating physiotherapeutic exercises in dogs [
18,
19,
20,
21,
22,
23,
24,
25], only a limited number of studies have examined their effects on vGRF and paw center of pressure (pCOP) [
16,
17]. PCOP analysis offers additional insight into postural control and limb loading. Parameters such as craniocaudal and mediolateral excursion, pCOP speed, area, and radius can be assessed noninvasively using force or pressure measurement systems [
12,
26]. These objective methods are widely used in both dynamic (e.g., walking, trotting) [
12,
16,
17,
26,
27,
28] and static (e.g., standing) conditions [
29,
30,
31,
32,
33,
34,
35]. The pCOP represents the point of application of the resultant vertical ground reaction force vector, which continuously shifts during ground contact to form the so-called pCOP path—a valuable indicator of balance and postural stability [
36].
Previous studies using pressure-sensitive plates have investigated the biomechanical effects of walking over obstacles. Significant changes in vGRF and pCOP parameters were observed, particularly in the hindlimbs. Impulse and stance duration increased, while pCOP path length decreased, with the most pronounced changes occurring in the leading hindlimb after crossing one or two obstacles. In contrast, the forelimbs showed minimal alterations [
16]. Similarly, wearing dog boots—especially on a single limb—resulted in asymmetrical vGRF distribution and significant changes in pCOP area, particularly in the contralateral limbs [
26]. These findings suggest that even moderate external challenges, such as surface irregularities or boot usage, can influence postural control and load distribution in healthy dogs.
Walking on different surfaces significantly affects gait mechanics in humans, as reflected by changes in vGRF and COP parameters. Specifically, surface-dependent adaptations include alterations in the magnitude and timing of the first and second vGRF peaks, changes in loading and unloading slopes, and modifications of COP trajectory characteristics. In addition, walking on compliant or uneven surfaces is associated with increased variability of these parameters. These changes are commonly interpreted as adaptive strategies to altered surface stiffness and stability, allowing individuals to modulate limb stiffness and impact attenuation to maintain overall gait stability and consistent center of mass control across different walking conditions [
37].
Comparable surface-related effects have also been reported in veterinary studies using pressure-based measurement systems. A preliminary pressure-plate study in sound ponies demonstrated that walking and trotting on a soft substrate resulted in reduced peak vertical force, vertical impulse, peak vertical pressure, and stance phase duration, accompanied by an increased hoof contact area and a more even toe–heel and mediolateral load distribution, particularly at impact. These findings support the concept that compliant surfaces dampen limb loading and promote a more homogeneous force distribution across the contact surface [
38].
Veterinary research in dogs to date has focused primarily on methodological considerations. In dogs, walking on various surfaces results in significant differences in pressure-sensitive walkway measurements in both lame and non-lame individuals, including changes in PFz, and IFz. However, these studies have mainly emphasized variability in measurement outcomes depending on the surface type [
39], without considering the potential therapeutic effects of walking on compliant or textured surfaces. Possible benefits related to proprioception, balance, or muscle activation remain unexplored and should be addressed in future research to evaluate the clinical relevance of surface-based interventions in veterinary rehabilitation.
The aim of this study was to evaluate the effects of surface compliance on vGRF and pCOP parameters during walk and trot in healthy adult dogs using a pressure measurement plate. For this purpose, dogs were measured at walk and trot under 4 conditions: a neutral surface and 3 yoga mats of increasing thickness. We hypothesized that pCOP parameters would significantly increase under soft-ground conditions, reflecting a greater postural stability challenge. Furthermore, we expected that the magnitude of these changes would increase with mat thickness.
4. Discussion
This study investigated the effects of soft ground on vGRF and pCOP parameters during walk and trot in healthy adult dogs using a pressure measurement plate. It was hypothesized that walking on softer surfaces would lead to increased pCOP displacement, reflecting a greater postural challenge. The hypothesis could not be confirmed based on the present data.
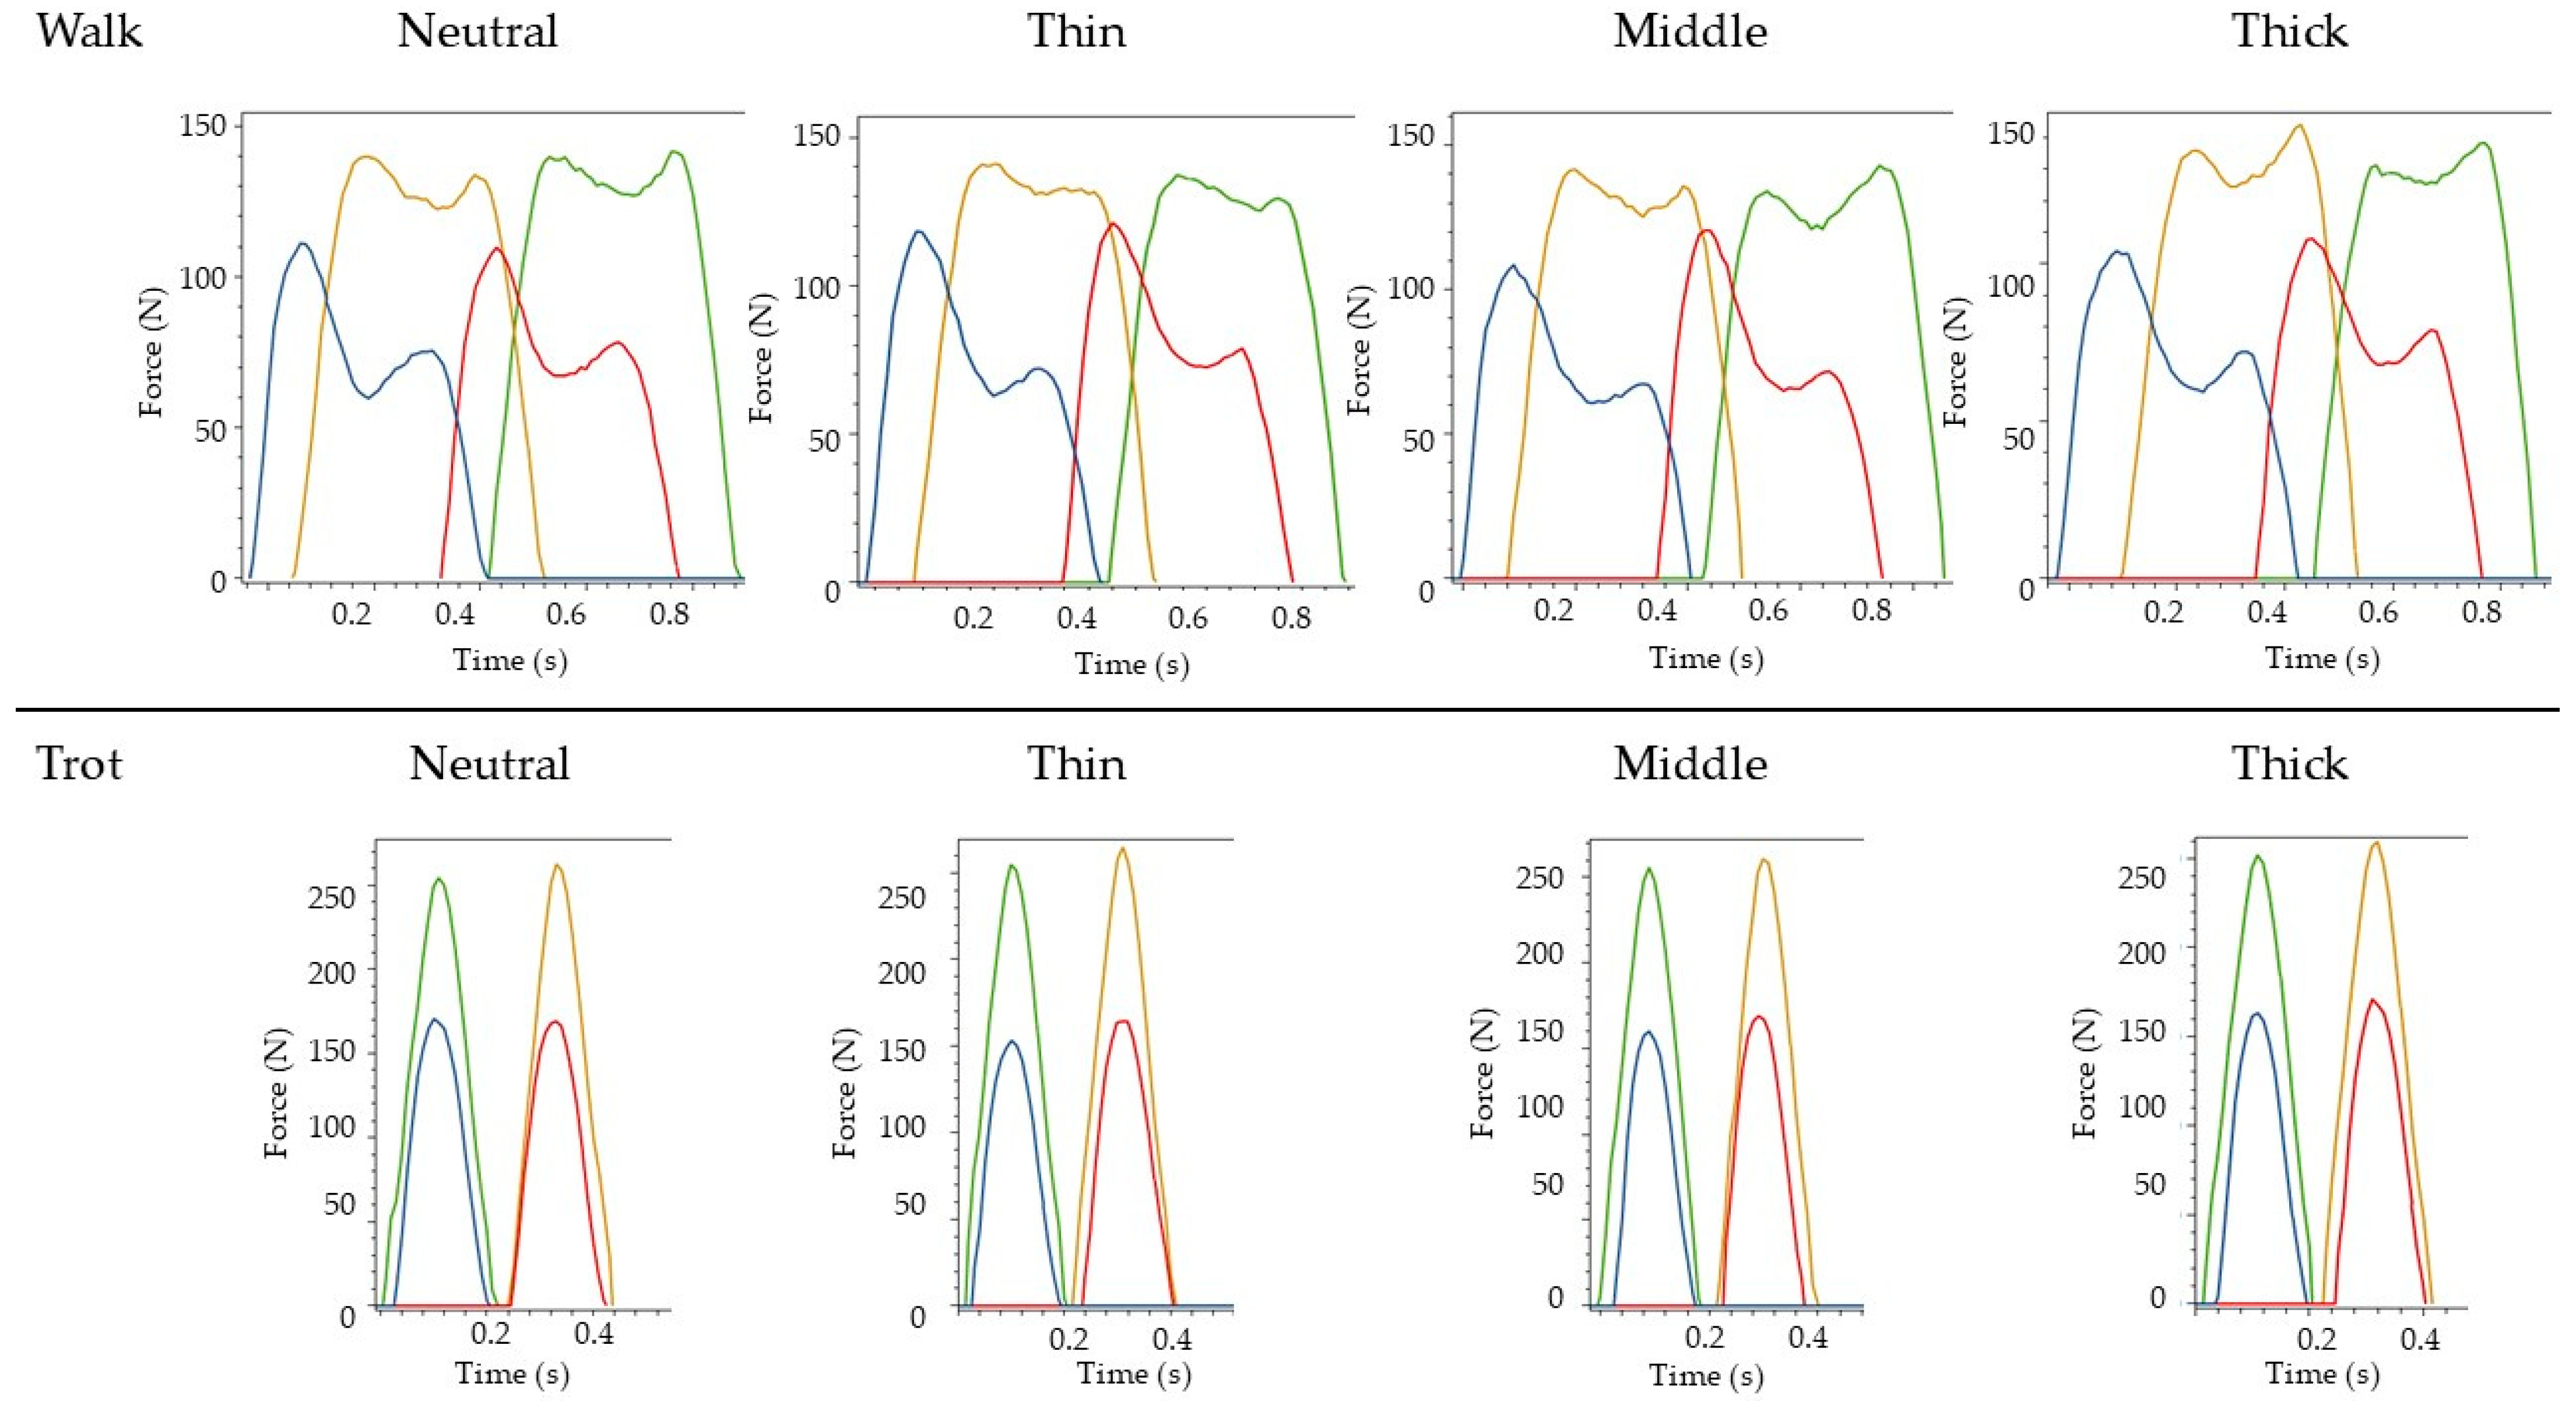
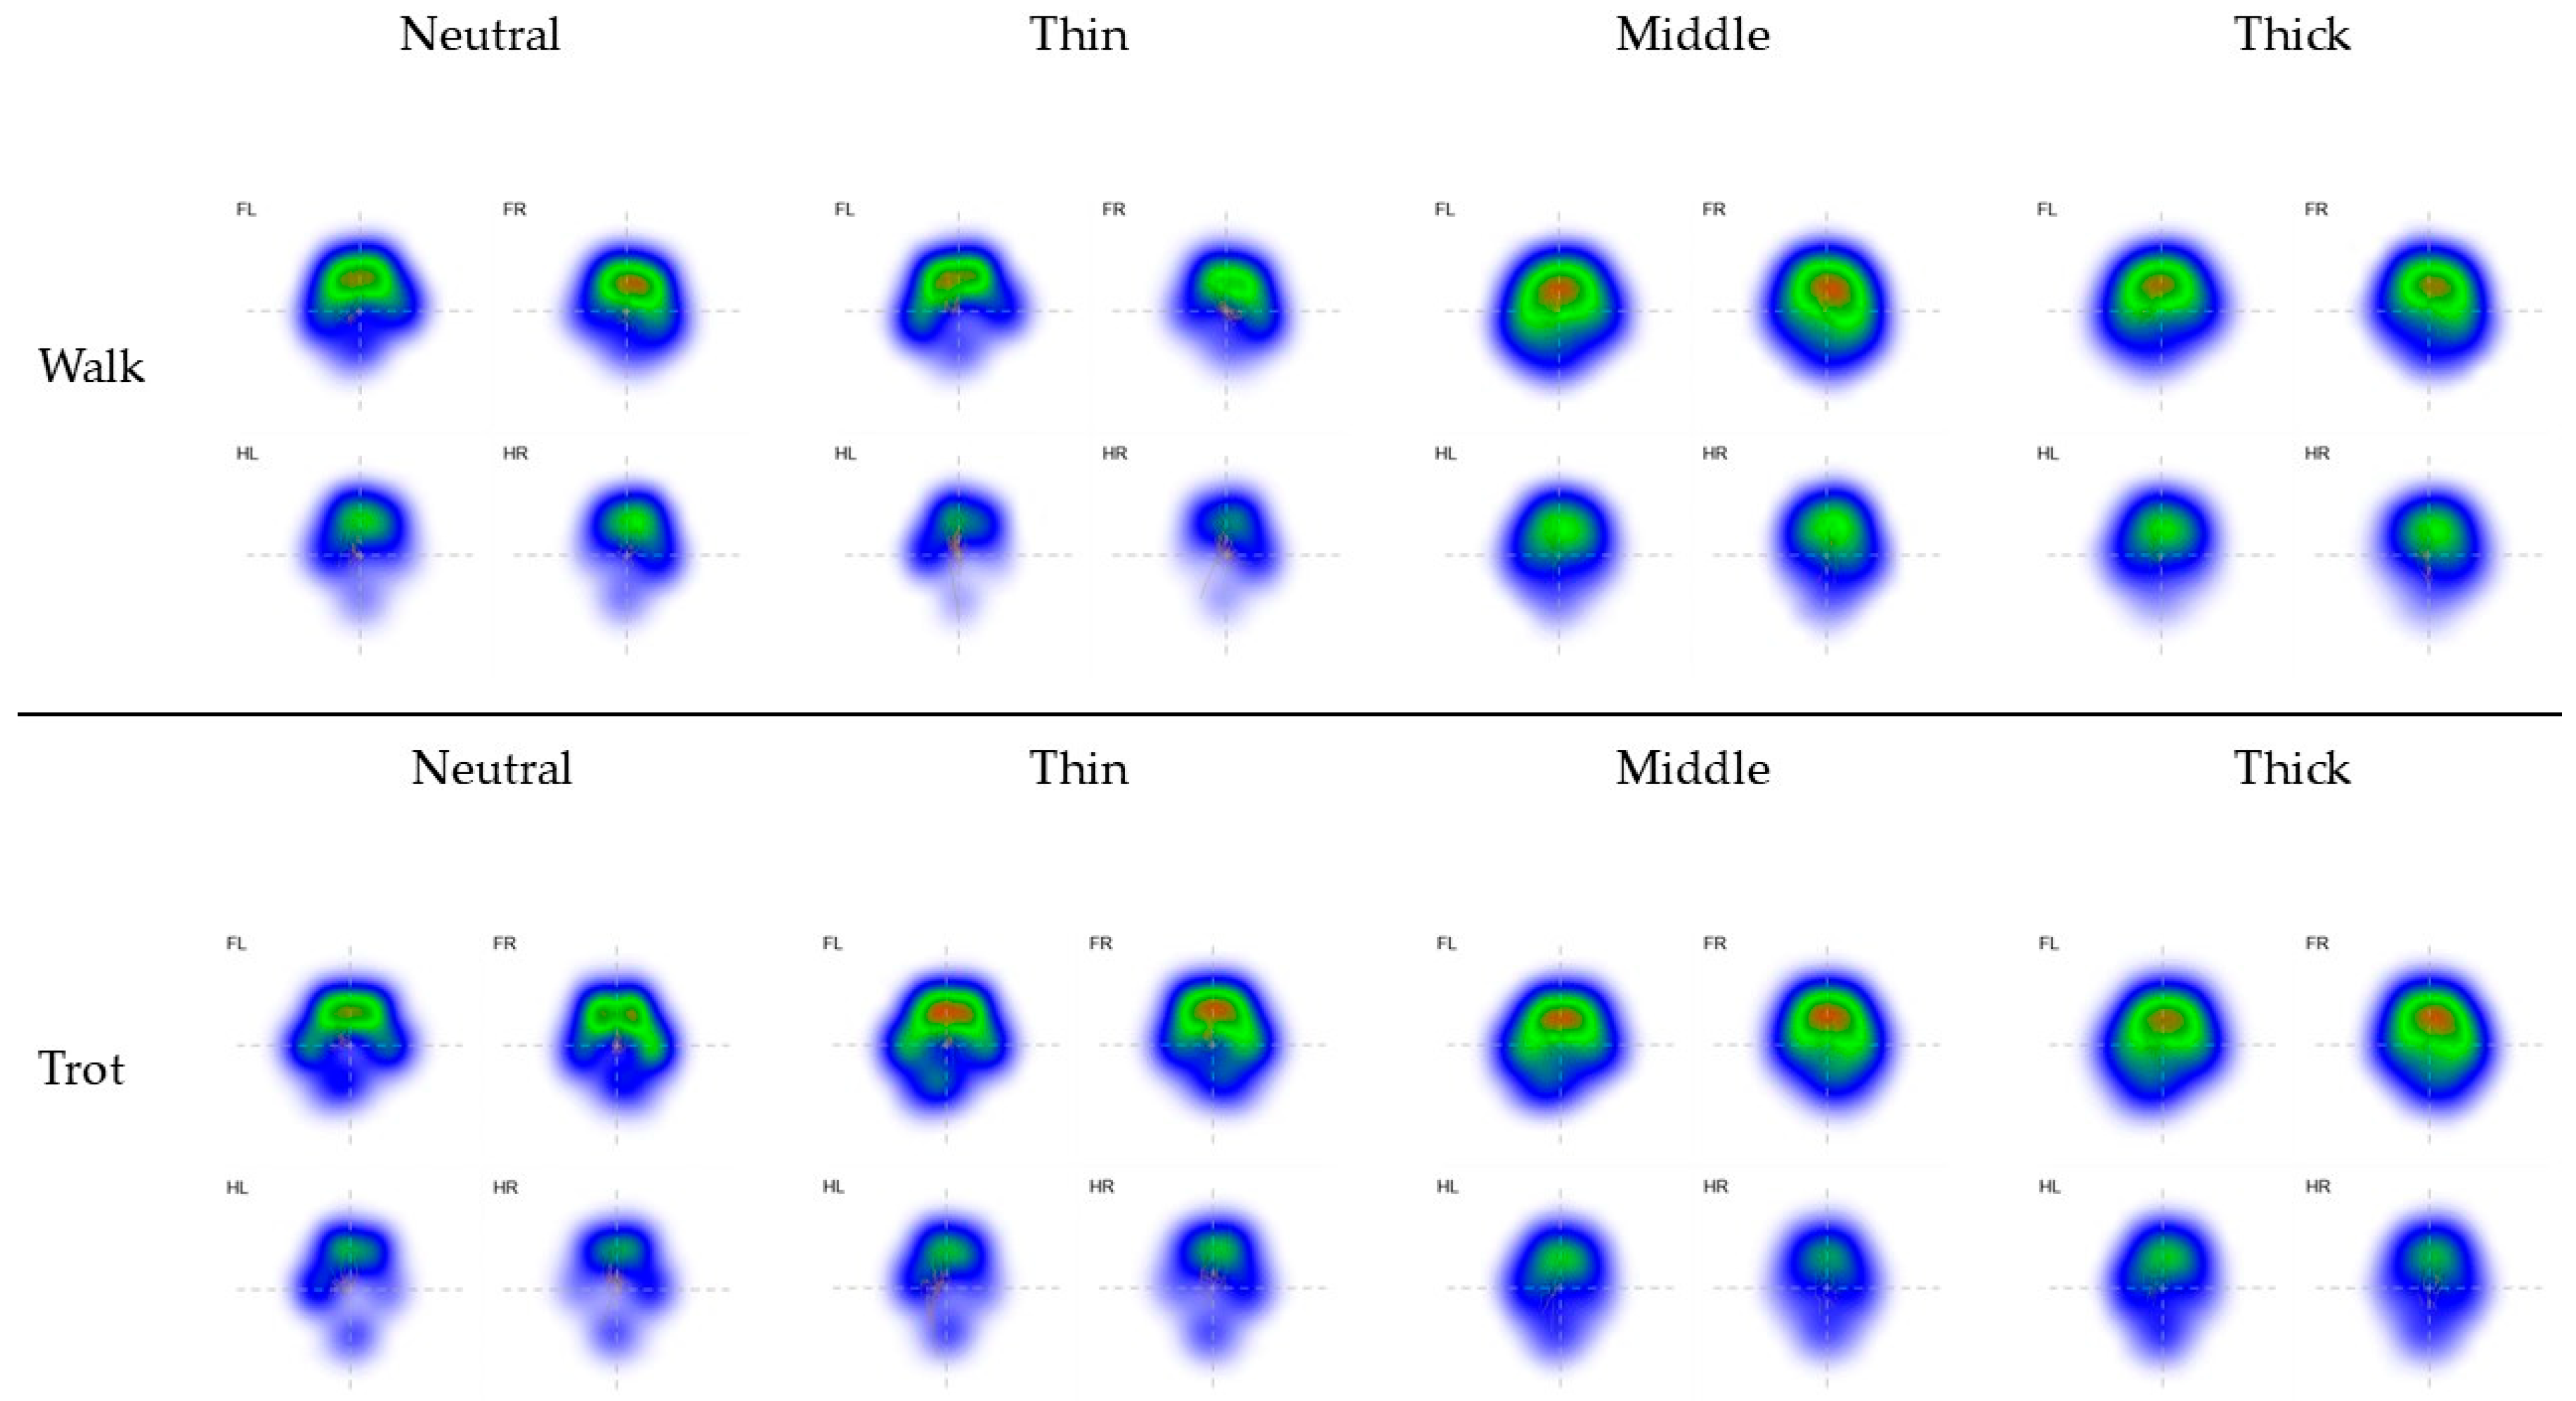
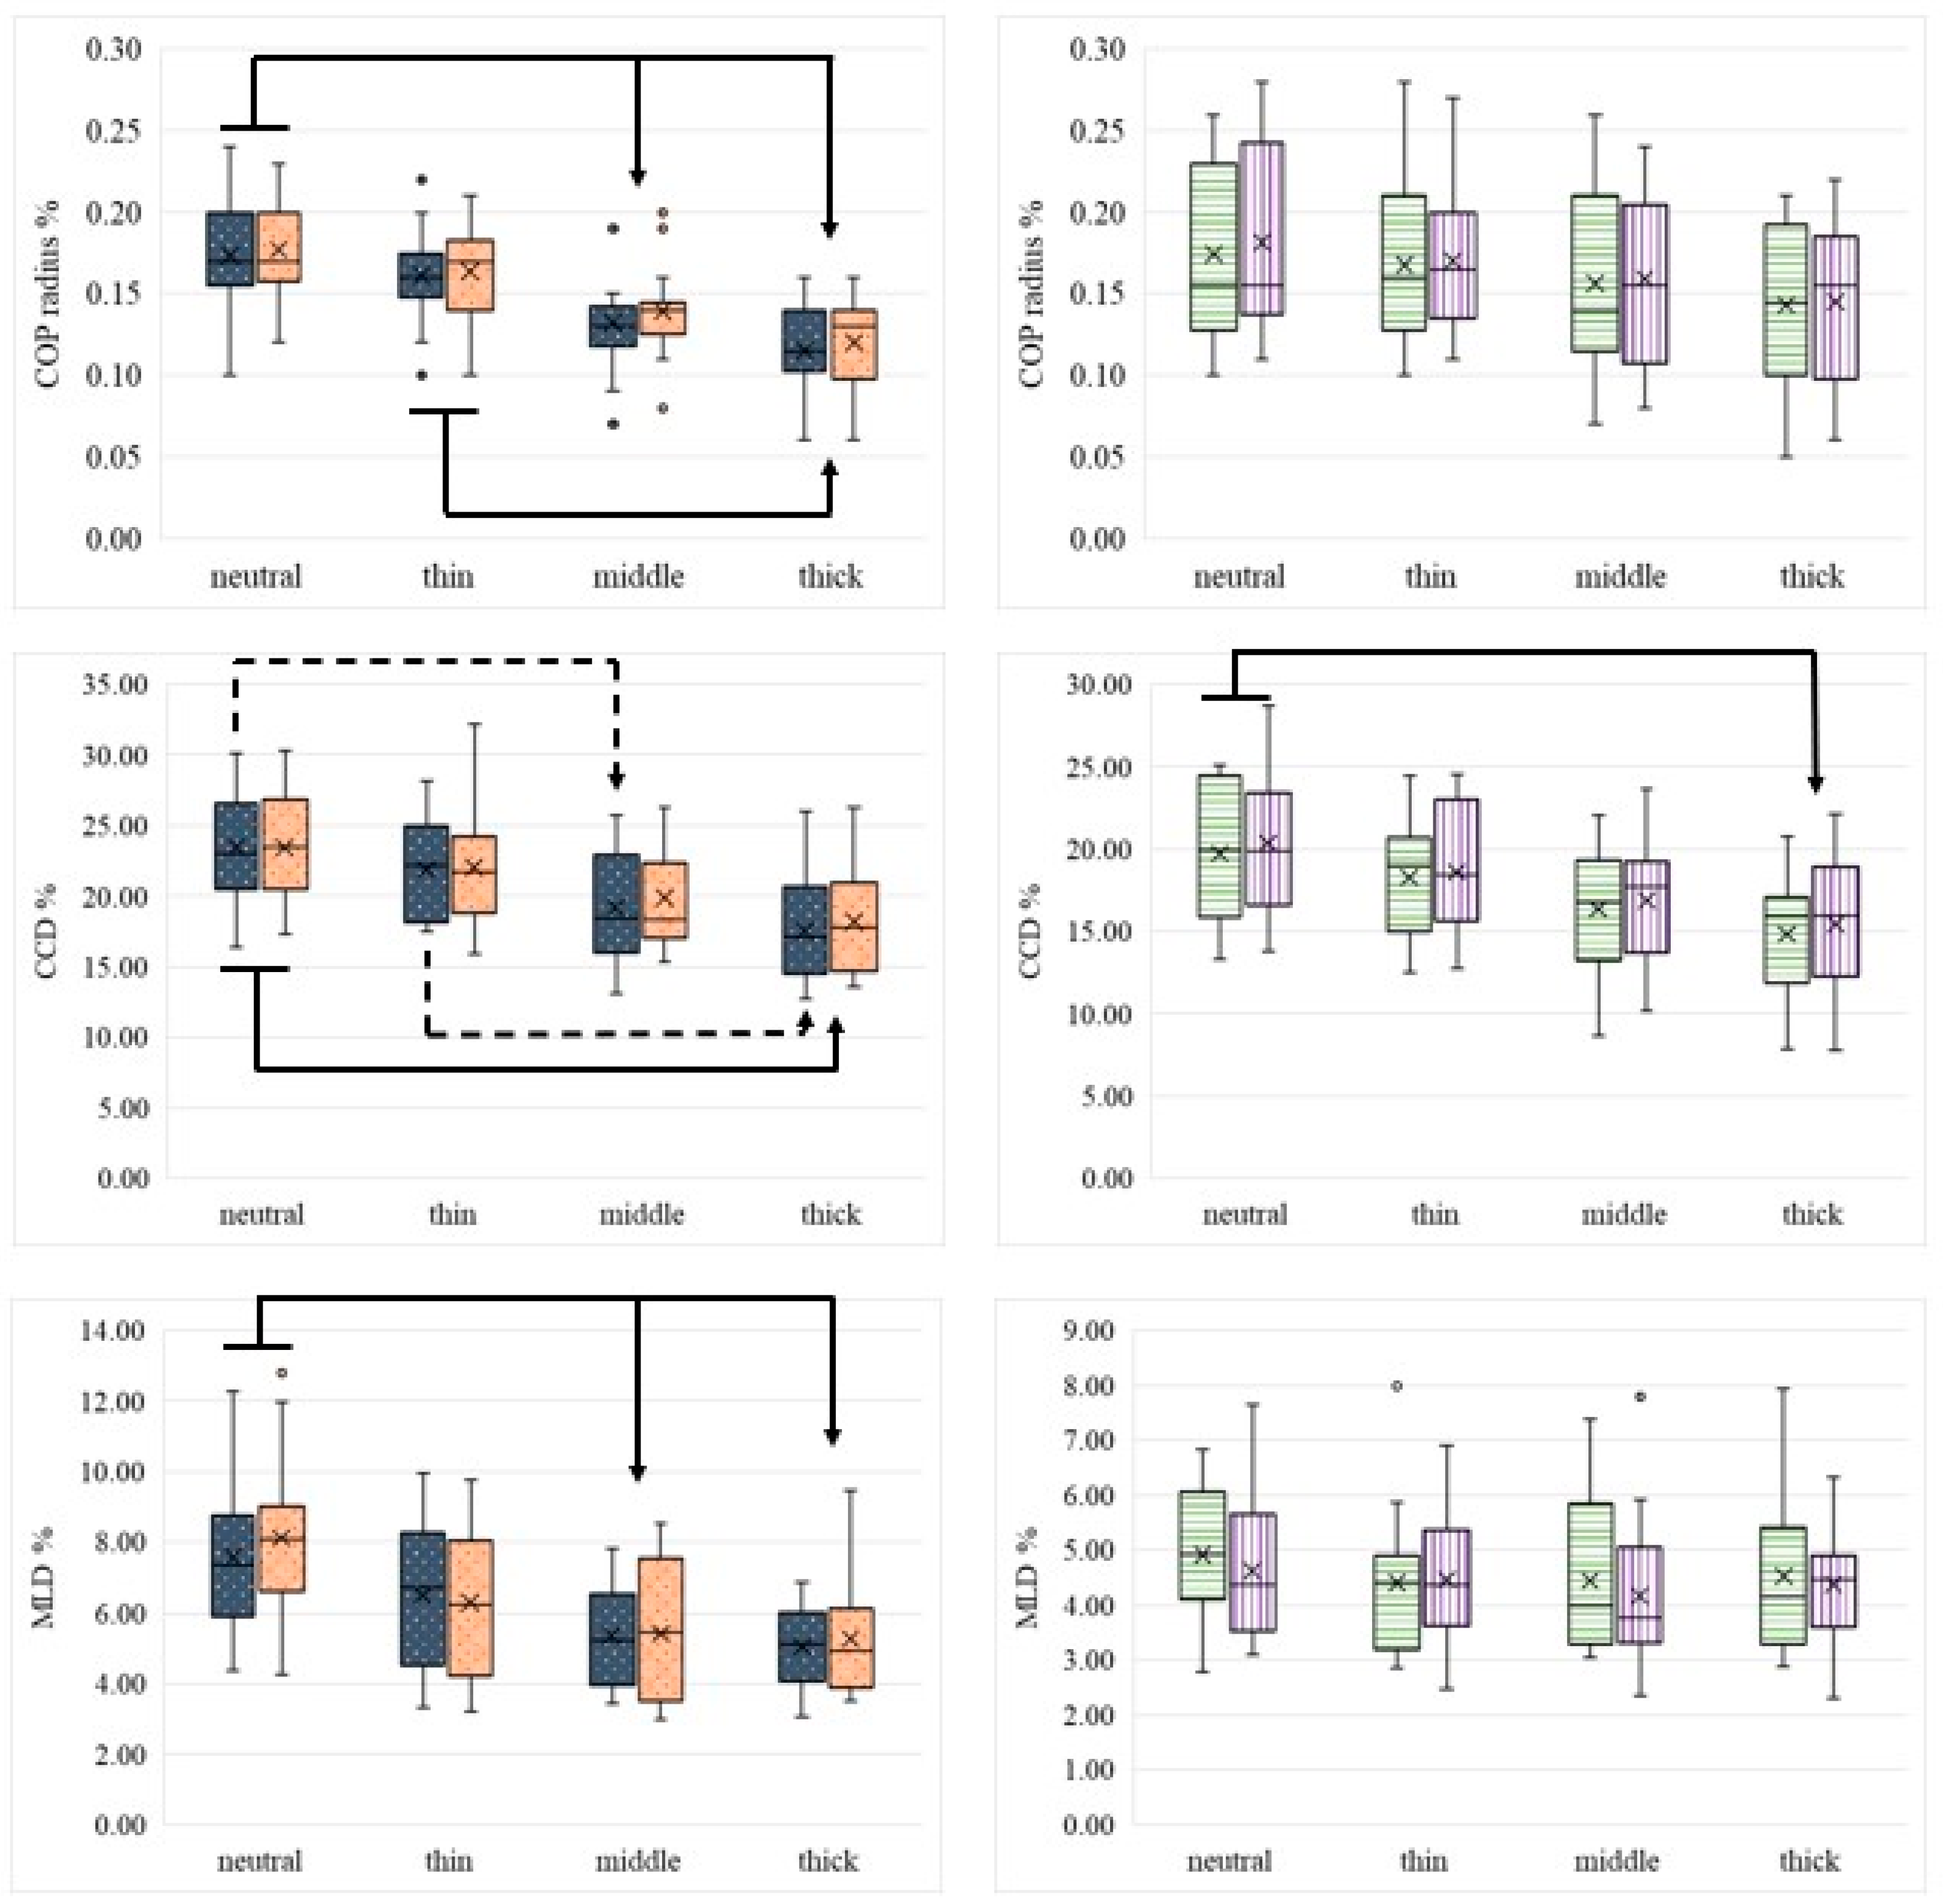
While most vGRF parameters, including PFz and IFz, remained unaffected by surface conditions, several pCOP-related variables showed consistent and significant changes. Specifically, reductions in pCOP radius, craniocaudal, and mediolateral displacement were observed with increasing mat thickness. These reductions likely reflect more controlled and constrained limb placement on compliant surfaces, indicating active neuromuscular strategies to maintain postural stability. Consistent with this interpretation, human studies have shown that walking on compliant or irregular surfaces is associated with shorter step lengths, reduced gait speed, and more compact pCOP trajectories [
37,
44], which are regarded as conservative adaptations to enhance stability under mechanically challenging conditions.
Importantly, the referenced human studies reporting comparable reductions in pCOP excursion employed pressure-sensing insoles, allowing for direct measurement at the foot–surface interface. While the similarity of the observed adaptations suggests comparable postural strategies in dogs, pressures in the present study were recorded beneath a compliant mat, introducing additional uncertainty. The material properties of the mat may lead to temporal delays and spatial redistribution of pressures, such that the recorded pCOP trajectories may not represent a one-to-one transfer of paw-applied forces. From a methodological perspective, surface compliance may also influence measurement sensitivity, as pressure absorption by soft mats can lead to an underestimation of vGRF and COP data [
45]. Consequently, although the observed reductions in pCOP displacement are indicative of more constrained limb placement and conservative postural strategies, these interpretations should be made with appropriate caution and within the context of the chosen measurement approach.
The effects of surface compliance on pCOP parameters differed between walking and trotting, both in extent and limb involvement. In walk, vGRF and COP area (%) and COP speed (mm/s) remained unaffected by surface conditions. However, COP radius (%) decreased significantly with increasing mat thickness, particularly in the forelimbs. CCD % and MLD % also decreased, mainly in the forelimbs but also affecting both hind limbs when comparing the neutral surface to the thickest mat.
In trot, pCOP parameters were generally more sensitive to changes in surface compliance. COP radius (%) decreased significantly across all limbs with increasing mat thickness. COP area (%) showed a decrease only in the left front limb, and pCOP speed (mm/s) decreased in both front limbs with increasing surface compliance. In studies with healthy young adults, strong negative correlations between right and left foot pCOP in the mediolateral direction were observed in approximately 67% of participants, indicating consistent asymmetry during quiet standing. This pattern suggests that participants tended to shift pressure toward the lateral border of the left foot while simultaneously applying greater pressure to the medial border of the right foot [
46]. Such asymmetry may reflect underlying musculoskeletal differences or leg dominance and has been discussed in the context of both functional and postural control mechanisms. Interestingly, single-leg balance tests in young adults revealed no significant differences between limbs [
47,
48], whereas soccer players demonstrated superior standing balance on their nondominant leg [
49]. Although these findings are based on human research, a similar rationale may be applied to interpret the limb-dependent pCOP variations observed in the present study.
Unlike walking, CCD% in trot decreased consistently in all limbs when comparing the neutral and thin surfaces to the middle and thickest mats. However, in contrast to walk, no significant changes were observed in MLD% during trot, suggesting that sagittal adjustments dominated postural strategies at higher speed.
Overall, the data indicate that trot induced more uniform and global postural adaptations across all limbs, particularly in pCOP radius and CCD%, whereas adaptations observed during walk were more localized to the forelimbs and varied between parameters. Notably, mediolateral COP measures during trot did not differ from the neutral condition when dogs walked on soft surfaces, suggesting that this gait does not impose additional mediolateral postural demands.
These findings likely reflect gait-specific differences in neuromuscular control requirements. During trot, simultaneous ground contact of contralateral limb pairs provides consistent bilateral stabilization of the body, allowing the center of mass to remain close to the support line [
50] and minimizing the need for additional mediolateral adjustments. Consequently, mediolateral COP control remains comparable to that observed under neutral conditions.
In contrast, during walk, postural control must be continuously adapted over the course of the stride cycle, which alternates between phases of tripedal support and bipedal support involving ipsilateral and contralateral limb pairs [
50]. The absence of a consistently stabilizing stance configuration necessitates tighter mediolateral and craniocaudal COP regulation to limit body sway. Clinically sound dogs appear capable of accommodating these increased control demands through reduced COP excursions, which may explain the more variable and limb-specific changes observed in pCOP parameters during walk.
Comparable gait-dependent postural strategies have been reported in juvenile dogs, where higher pCOP values were observed during walk compared to trot, indicating that the four-beat gait imposes greater postural control demands than the two-beat gait during growth [
40].
The dissociation between stable vGRF outputs and altered pCOP metrics indicates that vertical load distribution and balance control are regulated by different biomechanical systems. This finding aligns with previous studies in dogs, which demonstrated that vGRF values often remain stable even in orthopedically diseased limbs [
40] or under altered limb or surface conditions, such as when wearing protective dog boots, while pCOP parameters vary significantly [
26].
Our results also resonate with earlier findings in dogs walking over obstacles or performing precision tasks such as obedience heelwork, where significant pCOP adaptations occurred despite the absence of severe changes in vGRF [
16,
17]. A reduction in craniocaudal pCOP movement within the paws was previously connected with changes in paw pressure distribution during heel work. Similarly to this research, the findings of walking on soft surfaces can be interpreted as changes in paw roll over dynamic [
16]. Together, these findings reinforce the value of pCOP metrics as sensitive indicators of subtle neuromotor adjustments. Further, it can be suggested that walking on compliant surfaces represent a challenge for proprioception and is therefore a useful tool in canine rehabilitation.
In contrast to research on dogs with osteoarthrosis, where increased pCOP excursion and area were reported due to joint instability [
12], the current study found a reduction in pCOP displacement in sound dogs navigating compliant surfaces. Previous research has shown that in lame limbs, the craniocaudal pCOP displacement is shortened and cranialized compared to sound contralateral limbs [
27]. This shortening of the pCOP path has been linked to a reduced swing phase and more vertical paw placement at initial contact [
27,
51].
In addition to mechanical joint instability, it is also possible that joint damage associated with osteoarthrosis impairs proprioceptive input from periarticular structures, thereby contributing to altered pCOP excursions. This pattern parallels the reduced pCOP displacement observed in our study on soft surfaces, suggesting that similar stabilizing strategies, such as decreased limb excursion and more vertical limb positioning, may be employed even in healthy dogs to enhance postural stability under destabilizing surface conditions.
While a reduction in pCOP displacement during gait has not been widely reported in previous canine studies, a similar pattern has been observed in static postural assessments of the body COP. In a recent study investigating the effects of visual deprivation on standing balance in dogs, adult animals exhibited a significant decrease in CCD% and COP speed when blindfolded, compared to eyes-open condition. Interestingly, blindfolding did not show a significant effect in senior dogs [
30]. These findings suggest that healthy adult dogs may compensate for visual input loss by enhancing somatosensory control, particularly in the sagittal plane.
Although the context of that study was static posturography, and thus not directly comparable to dynamic gait analysis, the observed reduction in sway parameters under challenging sensory conditions aligns with the current findings. In both cases, healthy dogs appear to reduce COP displacement as part of a stabilizing strategy when confronted with instability—whether caused by surface compliance or sensory deprivation. This may reflect increased neuromuscular activity aimed at enhancing balance control, supporting the interpretation that a more compact COP path indicates an active postural stabilization mechanism.
From a methodological perspective, surface compliance can influence measurement sensitivity. Pressure absorption by soft mats may lead to an underestimation of vGRF and COP data, which has been described in related literature and must be considered when interpreting measurements obtained on compliant surfaces [
45]. In the present study, PCA increased with increasing mat thickness across all limbs and both gaits. As COP displacement parameters were normalized to PCA, these condition-dependent changes in contact area may additionally influence the magnitude of normalized COP parameters. Accordingly, the observed reductions in COP excursions should be interpreted as the combined result of altered paw–surface interaction mechanics, material-dependent pressure transmission, and the applied normalization procedure.
To the best of the authors’ knowledge, no studies have specifically quantified changes in canine PCA as a function of surface compliance. A plausible explanation for the observed PCA increase is greater deformation of the compliant mats under load, leading to a redistribution of pressure over a larger contact area and a more diffuse paw imprint. As the mechanical properties of the mats were not directly quantified, this interpretation remains speculative and highlights an important area for future investigation.
This study has several limitations. Only healthy adult dogs of medium body weight were included, which limits the transferability of the results to younger, geriatric or orthopedically affected animals. Measurements were conducted under controlled laboratory conditions with straight-line gait, which may not fully reflect functional adaptations during real-world movement scenarios such as turning, accelerating, or walking on uneven natural surfaces. Furthermore, soft surfaces may have absorbed part of the applied force before it reached the sensors, potentially leading to an underestimation of vGRF and pCOP values. As a consequence, interpretations related to limb placement and postural stability are subject to additional uncertainty, as the pressure mat may not fully capture the true magnitude and spatial distribution of forces exerted at the paw–surface interface [
45].
A further consideration is that limbs could have been grouped into fore- and hindlimbs to reduce model complexity. However, previous studies have shown that COP parameters can differ between left and right limbs despite symmetrical GRF [
40]. Therefore, symmetry in GRF does not necessarily imply symmetry in COP behavior, and limb-specific analyses were retained to avoid masking functionally relevant effects.
Future studies should include a broader range of dog populations, including geriatric animals and those with orthopedic or neurological conditions, to evaluate whether pCOP adaptations to compliant surfaces differ with age or pathology. Combining pressure plate data with kinematic or electromyographic analysis could provide deeper insight into the neuromuscular mechanisms underlying postural adjustments. In addition, testing a wider variety of surface materials and textures—including irregular or natural substrates—would improve ecological validity and may help identify clinically relevant thresholds for instability. These approaches could support the development of standardized surface-based physiotherapeutic interventions and objective outcome measures in canine rehabilitation.




 ,