


Abstract
This article focuses on generalized octonions which include real octonions, split octonions, semi octonions, split semi octonions, quasi octonions, split quasi octonions and para octonions in special cases. We make a classification according to the inner product and vector parts and give the polar forms for lightlike generalized octonions. Furthermore, the matrix representations of the generalized octonions are given and some properties of these representations are achieved. Also, powers and roots of the matrix representations are presented. All calculations in the article are achieved by using MATLAB R2023a and these codes are presented with an illustrative example.
1. Introduction
After Sir Rowan Hamilton discovered quaternions, Graves defined a new number system in 1843, which he named octonions [1]. Despite writing to Hamilton about his discovery in December 1843, Cayley independently arrived at the same number system, known as the Cayley numbers or Cayley algebra, and published his complete results in an article [2]. Afterwards, Hamilton explained that Graves had found and named these numbers before Cayley. This is why they are sometimes referred to as octonions and sometimes as Cayley numbers in the literature.
Octonions are primarily applied in theoretical physics. In the 1970’s, researchers attempted to use octonionic Hilbert spaces to study quarks. These structures are relevant to spacetime dimensions where super-symmetric quantum field theories are feasible. There have also been attempts to construct the Standard Model of elementary particle physics from octonionic frameworks [3].
Research involving octonions has extended to black hole entropy, quantum information science, string theory, and image processing. They have also proven useful in addressing the hand-eye calibration problem in robotics [3]. The Cayley algebra, which is non-associative and based on the Cayley numbers, is constructed according to the multiplication rules outlined in Table 1 [4].
Table 1.
The multiplication table of Cayley numbers.
The Cayley numbers, denoted by , refer to the set that forms the Cayley algebra, commonly known as the octonions.
It is the fact that includes some number sets for special cases.
- When , this condition yields the real octonions [5].
- When , this condition yields the split octonions [6].
- When , this condition yields the semi octonions [7].
- When , this condition yields the split semi octonions [8].
- When , this condition yields the quasi octonions [9].
- When , this condition yields the split quasi octonions [10].
- When , this condition yields the para octonions [11].
There are a lot of articles about these octonionic type numbers such as [12,13,14,15,16]. In [17], the physical signal s can be represented by an 8-dimensional number, which is an element of octonionic algebra, given by: where In this context, time is denoted by t, special coordinates are represented by , and refers to certain quantities. The dimensions of and w are those of . Additionally, the authors provided values for Planck’s constant and the speed of light. In their study, the authors linked the eight real parameters of octonions to spacetime coordinates, momentum, and energy, forming a complete octonionic basis. This description requires only the multiplication and distribution rules for three vector-like elements, facilitating the visualization of space’s 3-dimensional structure.
In literature, Cayley numbers is called also generalized octonion [18,19]. Furthermore, when viewed from the same perspective in the construction of 3-parameter generalized quaternions known in the literature [20], Cayley numbers is also be called 3-parameter generalized octonions (3PGO).
Any Generalized Octonion c is written in the form where is called the real part and is called the vector part of c. The summation of the Generalized Octonion and is
Also, these two Generalized Octonion are called equal when for . Multiplication a Generalized Octonion with a real scalar k is defined as
which satisfies the following properties:
By taking , , , the Generalized Octonion product of and is defined as follows:
In Table 2, the multiplication table of Generalized Octonions are shown. The product of is non-commutative, non-associative, and it is not alternative. But, in special case, the multiplication operation is alternative over real octonions and split octonions. The conjugate of a Generalized Octonion c is:
which satisfies the followings:
The symmetric -valued bi-linear form of the Generalized Octonion is defined as
or
The norm of c is:
which satisfies the followings:
Note that, the second property satisfies if The inverse of c is:
which satisfies the followings:
Note that, the second property satisfies if The inner product over is defined as
where and which satisfies the following algebraic properties:
Although its definition and a multiplication table for its construction with some of its basic properties such as its norm, are mentioned in the literature, Generalized Octonion have not been researched much since the old years when they were introduced. In fact, Generalized Octonions, which contain many types of octonions, have been studied as real octonions in the literature [5]. The multiplication table has given in an exercise in [4] and the algebraic structure is examined in [21]. In this article, we investigate the classifications of the Generalized Octonions and we give the matrix representations for them. Also we get De Moivre formula for Generalized Octonions. In this way, the root theorem is presented. In the final section, we provide an illustrative example for all the results provided in the previous sections. In the Appendix A, we give the Matlab function and codes for all calculations.
Table 2.
The multiplication table of Generalized Octonions.
2. The Inner Product Space
The inner product space is identified with pure Generalized Octonion whose real parts are zero. So, in this section some necessary definitions and some properties about 7-tuples are given.
Definition 1.
Let are arbitrary 7-tuples in represented as
and
The inner product of them is defined as
where
Theorem 1.
The inner product function satisfies the following properties:
(1) Linearity:
(2) Symmetric Property: .
(3) Non degenerate Property: When are all nonzero real numbers, for all , then .
Proof.
Proofs can be easily done by basic substitution. □
It is important to note that property (3) does not qualify as an inner product in the usual sense, because it lacks positive-definiteness. In particular, the quadratic form may not be positive for nonzero A. The condition of positive-definiteness has been replaced with the weaker requirement of non-degeneracy, acknowledging that while all positive-definite forms are non-degenerate, not all non-degenerate forms are positive-definite.
Corollary 1.
With these properties is an inner product space with the inner product defined in Definition 1 if are all positive real numbers.
Definition 2.
Let are arbitrary 7-tuples in represented as
and
The vector product of these two vectors is given as:
Equivalently, the vector product can be stated as:
Theorem 2.
The vector product, also known as the cross product, satisfies the following properties:
Proof.
Proofs can be easily done by basic substitution. □
3. Some Properties of Generalized Octonion
In this section, we give some algebraic identities for the Generalized Octonion such as an alternative expression for multiplication, right/left matrix representations, classification with respect to inner product and vector parts.
Theorem 3.
Let and be two Generalized Octonion, then
where is the inner product of vector parts of the and which is given in Definition 1, and is the vector product of vector parts of the and which is defined in Definition 2.
Proof.
By substituting the definitions of inner product and vector product in the multiplication of and , we can directly prove the theorem. □
The Generalized Octonion are classified into 3 types when considering the value of the inner product with itself are positive, negative and zero.
where Also, the Generalized Octonion are classified into 3 types according to the vector part of them. Now, the classifications are given with respect to the sign of the inner product and the vector parts, respectively.
Definition 3.
Let be a Generalized Octonion. If , then c is called a spacelike Generalized Octonion, if , then c is called a timelike Generalized Octonion and if , then c is called a lightlike Generalized Octonion.
- When , the Generalized Octonion c is said to have a spacelike vector part.
- When , the Generalized Octonion c is said to have a timelike vector part.
- When , the Generalized Octonion c is said to have a lightlike vector part.
Let be a Generalized Octonion and be a unit vector in , then there are five classes of the polar representation of c with respect to its inner product and vector part.
(i) If the inner product of c is negative (so, c is a timelike Generalized Octonion), then it is written as
where
and is timelike, Refs [18,19].
(ii) If the inner product of c is positive (so, c is a spacelike Generalized Octonion) and the vector part of c is timelike, then it is written as
where
and is timelike, Refs [18,19].
(iii) If the inner product of c is positive (so, c is a spacelike Generalized Octonion) and the vector part of c is spacelike, then it is written as
where
and is spacelike, Refs [18,19].
(iv) A Generalized Octonion c with an inner product of zero (referred to as a lightlike Generalized Octonion) can be expressed in the form as:
where
and is a unit vector in satisfying Given that:
and since the condition:
is satisfied, confirming that is indeed a unit vector.
(v) If c is a Generalized Octonion with the lightlike vector part, then
where
is a unit vector in with Note that the vector part of c is lightlike, so , can be determined as
Since , then
In Table 3, the polar forms of Generalized Octonions are shown.
Table 3.
The polar forms of the Generalized Octonions.
4. De Moivre’s Formulas of Generalized Octonion
This section introduces De Moivre’s formulas, which provide a method for finding the powers and roots of Generalized Octonions through their polar representations.
Theorem 4.
Let c be a unit Generalized Octonion in polar form and its inner product be negative. Then, we get
if n is an odd integer, and
if n is an even integer.
Consider the unit Generalized Octonion with a positive inner product, implying that its vector part is timelike. Then, we obtain
for all integers n.
Consider the unit Generalized Octonion , with a positive inner product, implying that its vector part is spacelike. Then, we have
for all [18,19].
Theorem 5.
Let consider the polar form of a Generalized Octonion whose inner product is zero. Then, we get
for all integers
Proof.
We use the mathematical induction over n. We assume that c is a Generalized Octonion whose inner product is zero and satisfies. Then, and
□
Theorem 6.
Let be a unit Generalized Octonion whose vector part is lightlike. Then, we obtain
for all integers
Proof.
From the mathematical induction over n, we get the proof because the fact . □
In Table 4, the De Moivre’s formulas for the Generalized Octonions are shown.
Table 4.
De Moivre’s formulas for the Generalized Octonions.
5. Roots of Generalized Octonion
In this section, for any integer n, the roots of a Generalized Octonion or in other words the solutions of the equation is found.
Theorem 7.
Let be a unit Generalized Octonion in polar form whose inner product is negative.
(i) For even values of n, the equation does not have a root.
(ii) For odd values of n, there exist exactly one root of the equation calculated as
where
Let be a Generalized Octonion and unit where the inner product (positive), indicating that the vector part is timelike.
(i) When n is even, there are four distinct roots of the equation and they are given as follows:
where
(ii) When n is odd, there exists exactly one root of the equation and the root is
where
Let be a Generalized Octonion an unit where the inner product (positive), indicating that the vector part is spacelike. Then, there exist n distinct roots as in the form
where
Note that in special cases, the Equations (3), (4) and (6) are given as propositions in [18].
Theorem 8.
Let be a lightlike Generalized Octonion where the inner product of c be zero. Then,
(i) If n is even, then has two distinct roots are as follows:
where .
(ii) If n is odd, then the exactly one root of is
where
Proof.
The proof can be achieved, easily. □
Theorem 9.
Let be a unit Generalized Octonion with the lightlike vector part.
(i) If n is even, then has two distinct roots for The roots are as follows:
But, the equation has no roots for
(ii) If n is odd, then has exactly one root which is in the following form:
Proof.
One can prove the formula directly. □
Now, by using the Hamilton’s operators, we introduce the right/left matrix representations of the numbers in Also, we obtain some identities for the representations.
Definition 4.
Let and be two Generalized Octonion, then right matrix representation and the left matrix representation are defined as
respectively, and are also called Hamilton’s operator.
Also, the Hamilton’s operators could be represented by the matrices as follows:
In order to obtain the representation matrix, any Generalized Octonion is multiplied from the right side by , respectively, and the coefficients of the equations in each row correspond to the elements in the columns of the matrix. Similarly, by multiplying from the left side by the Cayley units, we get the following matrix.
Theorem 10.
The functions and are bijective.
Proof.
Let be a Generalized Octonion and the function be defined as above. Then, the kernel of is
So, is one to one. The image of is
By restricting the image set, is subset of the real matrices with size 8 over So, is onto. Similarly, it is directly seen that is bijective, too. □
Lemma 1.
Let and be two Generalized Octonions and . Then,
Theorem 11.
Let be two Generalized Octonions and denote the real vector representation of . Then
Proof.
The real vector representation of can be rewritten in the form
where and is the transpose of the 8-length vector So, we get
□
At this part of the article, the powers and roots are given for only the right representation matrix Surely, the similar results can be stated for the left representation matrix
Theorem 12.
If is a unit generalized octonion with the inner product having negative value and a unit timelike vector , the right representation of the generalized octonion can be written as follows:
For any positive integer n, the power of the matrix is given as:
where
If is a unit generalized octonion with the inner product having positive value and a unit timelike vector , the right representation of the generalized octonion can be written as follows:
For any positive integer n, the power of the matrix is given as:
where
If is a unit generalized octonion with the inner product having positive value and a unit spacelike vector , the right representation of the generalized octonion can be written as follows:
For any positive integer n, the power of the matrix is given as:
If is a unit Generalized Octonion with a zero inner product (i.e., a lightlike Generalized Octonion), the right representation of the Generalized Octonion can be formulated as follows:
For any positive integer n, the power of the matrix is given as:
If is a unit generalized octonion with the lightlike vector part, the right representation of the Generalized Octonion can be depicted as:
For any positive integer n, the power of the matrix is demonstrated as:
Proof.
By using the mathematical induction over n, and using the trigonometric identities for summation, the proofs can be derived, clearly. □
Theorem 13.
Let be the right representation matrix of the generalized octonion c which is unit and has negative inner product and be a unit timelike vector with length 7. Then, the equation or has the following solutions:
(i) If n is even, then there is no solution.
(ii) If n is odd, then there is only unique solution such that
where
Proof.
By using the Theorem 12, power of the root matrix is given . So, the theorem is thus proven. □
Theorem 14.
Let be the right representation matrix of the generalized octonion c which is unit and has positive inner product and be a unit timelike vector with length 7. Then, the equation or has the following solutions:
(i) If n is even, then there are distinct solutions such that
where
where
where
where
(ii) If n is odd, then there is unique solution as follows
where
Proof.
By using the Theorem 12, power of the and the given matrix in (ii) are equal . This completes the proof. □
Theorem 15.
Let be the right representation matrix of the generalized octonion c which is unit and has positive inner product and be a unit spacelike vector with length 7. Then, the equation or has solutions in the following form
where
Proof.
The proof is similar to Theorem 13. □
Theorem 16.
Let be the right representation matrix of the generalized octonion c which has zero inner product and be a unit vector with length 7. Then, the equation or has the solutions in the following forms
(i) If n is even, then there are two solutions such that
where
(ii) If n is odd, then there is unique solution such that
where
Proof.
The proof can be shown using a method analogous to the one used in Theorem 13. □
Theorem 17.
Let be the right representation matrix of the generalized octonion c which has zero inner product and be a unit lightlike vector with length 7. Then, the equation or has the solutions in the following forms
(i) If n is even and is positive, then there are two solutions such that
Note that if is negative, then there is no solution.
(ii) If n is odd, then there is unique solution such that
Proof.
The proof can be given similar to Theorem 13. □
6. An Application
In this section, we define the Matlab functions for calculations when we consider the Generalized Octonion c is in the real vector representation given in Theorem 11. Let us get and be any real numbers. Then,
- The product of and isand by taking we get
- The inner product of and is and by taking we get
- The norm of is and the norm of is By taking we get
- The inverse of does not exist and the inverse of isBy taking we get
- The inner product of the vector parts of is and by taking we get
- The vector product of the vector parts of is and by taking we get
- The right representation of the Generalized Octonion isand by taking we get
- The left representation of the Generalized Octonion isand by taking we get
- and By taking the inner product so is a lightlike Generalized Octonion. Thus, where Note that On the other hand, the inner product so is a spacelike Generalized Octonion. Also, so is a Generalized Octonion with spacelike vector part. Thus, where
- The 9th power of is . The right representation of is acquired from Theorem 12 case (iii) as follows:Then, the 9th power of is
- The 3-roots of the equation are follows:
7. Conclusions
The purpose of this research is to examine some properties of Generalized Octonion which contain real octonions, split octonions, semi octonions, split semi octonions, quasi octonions, split quasi octonions and para octonions in special cases. The Table 5 summarizes some studies in the literature on special cases with respect to .
Table 5.
Research articles in the literature on special cases of .
The generalized octonions are given in polar forms and are classified with respect to their inner products and vector parts. Powers and roots are investigated for the Generalized Octonions. Additionally, the matrix representation of Generalized Octonions are given with the algebraic properties. This section also presents the computation of powers and roots in the matrix representation of the Generalized Octonions. Moreover, MATLAB R2023a is used as a calculation tool for all results throughout the article and the MATLAB functions are defined in the last section with a numerical example, together.
Funding
This research received no external funding.
Data Availability Statement
Data are contained within the article.
Acknowledgments
The authors appreciate the anonymous referees for their careful corrections and valuable comments on the paper.
Conflicts of Interest
The author declares no conflict of interest.
Abbreviations
The following abbreviations are used in this manuscript:
| The set of the Cayley numbers | |
| 3PGO | 3-parameter generalized octonions |
| Real part of the Generalized Octonion | |
| Vector part of the Generalized Octonion | |
| The conjugate of the Generalized Octonion | |
| The norm of the Generalized Octonion | |
| The inverse of the Generalized Octonion | |
| Inner product of 7-tuples vectors | |
| Vector product of 7-tuples vectors | |
| The right matrix representation of the Generalized Octonion | |
| The left matrix representation of the Generalized Octonion | |
| ker | The kernel of any transformation |
Appendix A
In this section, the MATLAB codes for the example in Application Section are presented.
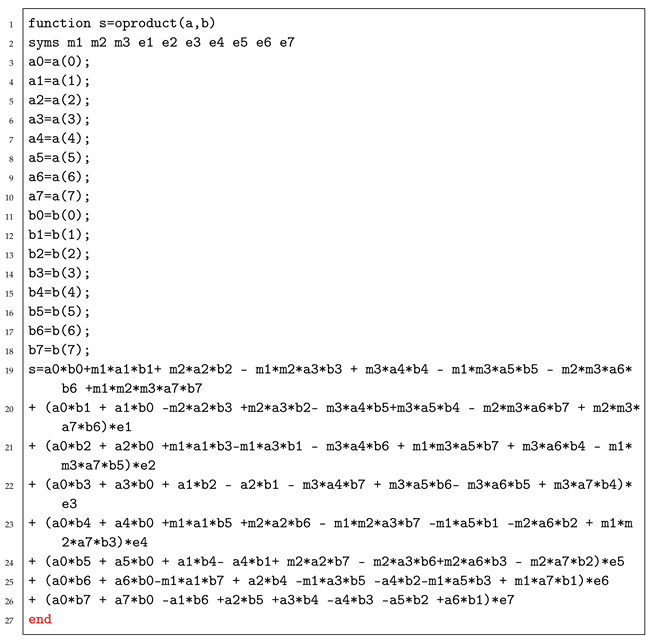
- The MATLAB function for multiplication of any two Generalized Octonion are as follows:
- The MATLAB codes for calculating the example above are written as:
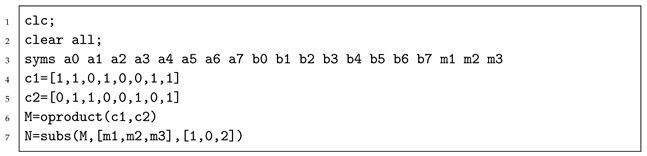 The other calculations are only given with the MATLAB functions. With similar way, one can run the calculation codes.
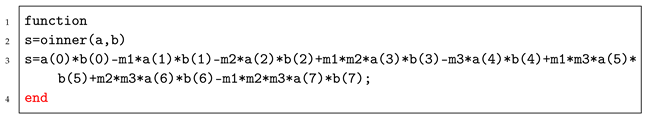
- The MATLAB function for inner product of any two Generalized Octonion are as follows:
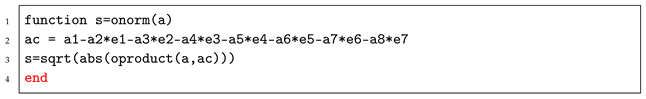
- The MATLAB function for norm of any Generalized Octonion is defined as follows:
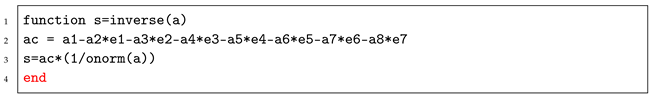
- The MATLAB function for inverse of any invertible Generalized Octonion is given as follows:
- The MATLAB function for vector inner product of vector parts of any two Generalized Octonion is defined as follows:
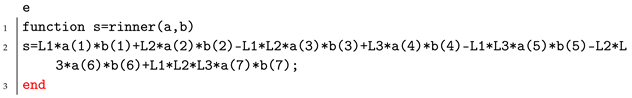
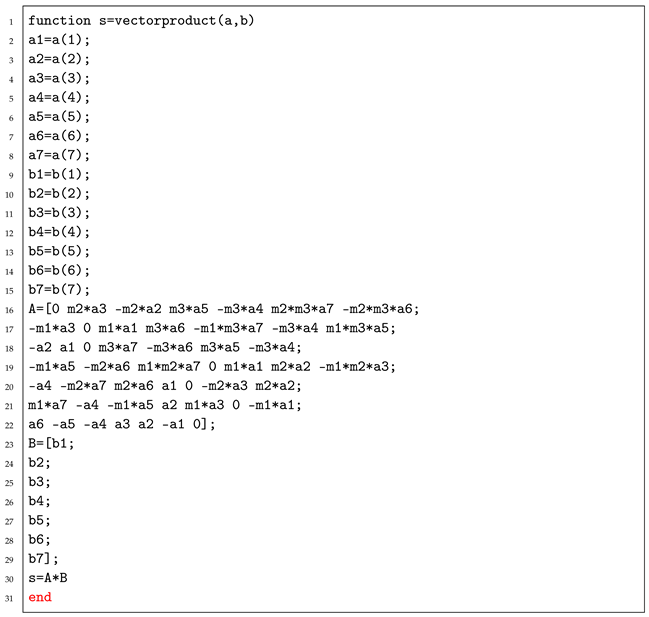
- The MATLAB function for calculating the vector products of vector parts of any two Generalized Octonion is as follows:
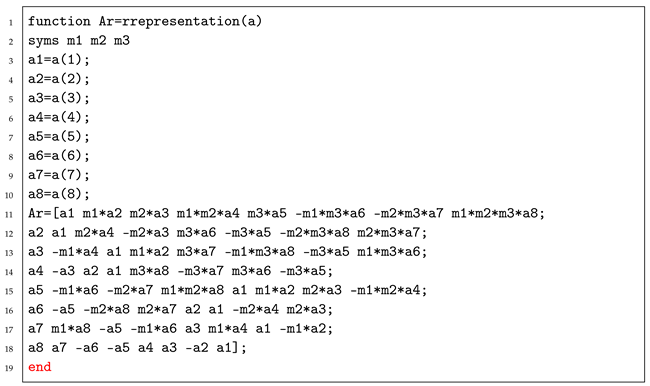
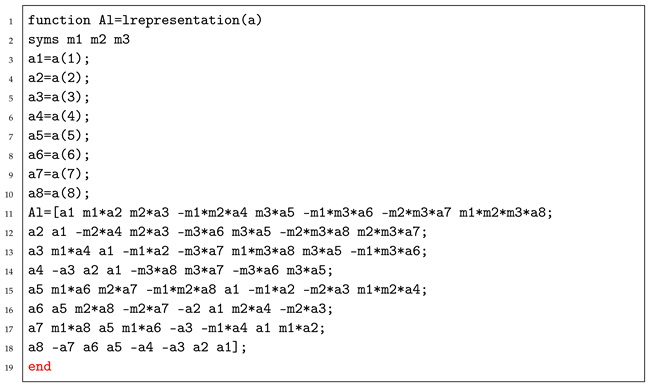
- The MATLAB function for the right representation of any Generalized Octonion is given as follows:
- The MATLAB function for the left representation of any Generalized Octonion is as follows:
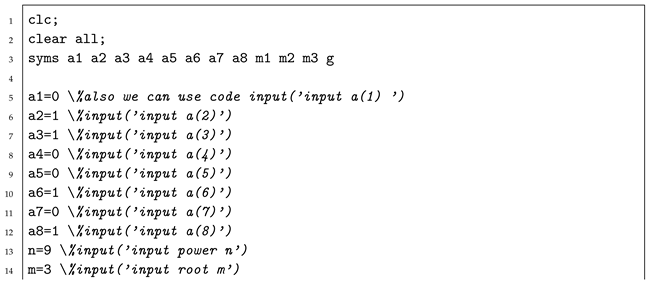
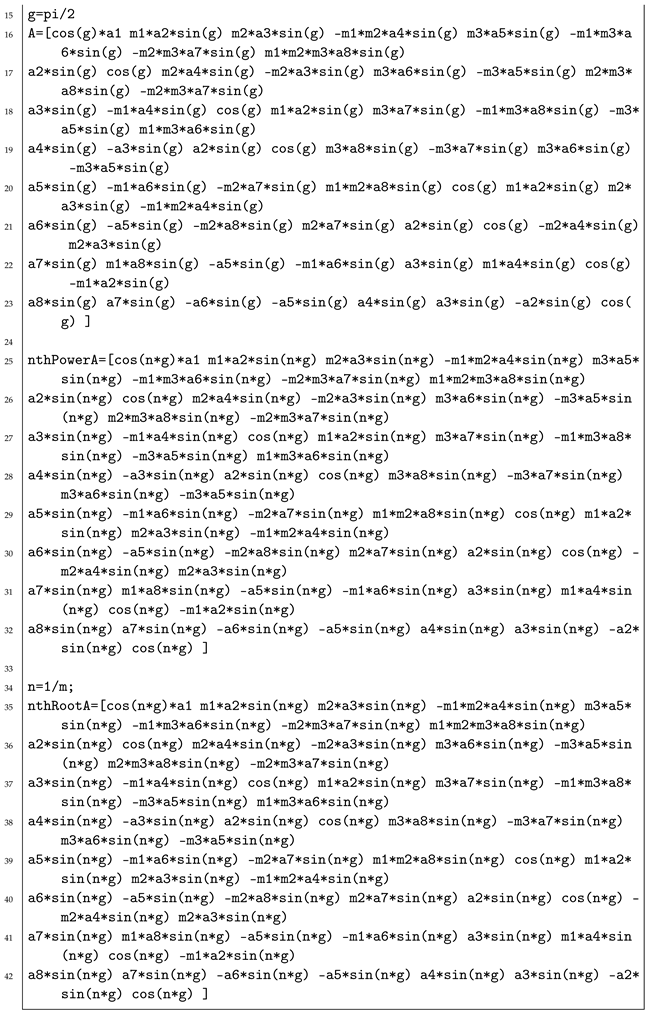
- The MATLAB function for the n-power and m-root of any Generalized Octonion is as follows:
References
- Hamilton, W.R. Elements of Quaternions; Longmans, Green and Co: London, UK, 1866. [Google Scholar]
- Cayley, A. On Jacobi’s Elliptic Functions, in Reply to the Rev. B. Bronwin, and on Quaternions. Philos. Mag. 1845, 26, 208–211. [Google Scholar]
- Wikipedia. Available online: https://en.wikipedia.org/wiki/Octonion (accessed on 25 September 2024).
- Zhevlakov, K.A.; Slinko, A.; Shestakov, I.; Shirshov, A.I. Rings That Are Nearly Associative; Academic Press: London, UK, 1982. [Google Scholar]
- Baez, J. The octonions. Bull. Am. Math. Soc. 2002, 39, 145–205. [Google Scholar] [CrossRef] [Scilit]
- Carmody, K. Circular and hyperbolic quaternions, octonions, and sedenions. Appl. Math. Comput. 1988, 28, 47–72. [Google Scholar] [CrossRef] [Scilit]
- Jafari, M. A viewpoint on semi-octonion algebra. J. SelçUk Univ. Nat. Appl. Sci. 2015, 4, 46–53. [Google Scholar]
- Jafari, M. Introduction to Split Semi-Octonion: Algebra and Analysis. 2015. Available online: https://www.researchgate.net/publication/281454836_Introduction_to_Split_Semi-Octonion_Algebra_and_Analysis (accessed on 11 November 2024).
- Jafari, M. An Introduction to Quasi-Octonions and Their Representation. 2015. Available online: https://www.researchgate.net/publication/281202641_An_Introduction_to_Quasi-Octonions_and_Their_Representation (accessed on 11 November 2024).
- Jafari, M. The fundamental algebraic properties of split quasi-octonions. DUFED 2016, 5, 118–122. [Google Scholar]
- Jafari, M. On The Para-Octonions:A Non-Associative Normed Algebra. MFBD 2016, 28, 95–99. [Google Scholar]
- Schray, J.; Mongue, A.A. Octonionic Representations of Clifford Algebras and Triality. Found. Phys. 1996, 26, 17–70. [Google Scholar] [CrossRef] [Scilit]
- Alo, J.; Akbıyık, M. On split-octonionic curves. Log. J. Igpl 2024. [Google Scholar] [CrossRef] [Scilit]
- Tian, Y. Matrix representations of octonions and their applications. Adv. Appl. Clifford Algebras 2000, 10, 61–90. [Google Scholar] [CrossRef] [Scilit]
- Akbıyık, M. On Powers and Roots of Split Octonions. J. Math. 2023, 2023, 2314–4629. [Google Scholar] [CrossRef] [Scilit]
- Sabinin, L.V.; Sbitneva, L.; Shestakov, I.P. Non Associative Algebra and its Applications, 1st ed.; A Series of Lecture Notes in Pure and Applied Mathematics; Chapman& Hill, CRC Press: Boca Raton, FL, USA, 2006. [Google Scholar]
- Gogberashvili, M. Octonionic geometry. Adv. Appl. Cliford Algebr. 2005, 15, 55–66. [Google Scholar] [CrossRef] [Scilit]
- Flaut, C.; Shpakivskyi, V. An efficient method for solving equations in generalized quaternion and octonion algebras. Adv. Appl. Clifford Algebras 2015, 25, 337–350. [Google Scholar] [CrossRef] [Scilit]
- Leite, F.S.; Vitoria, J. Generalization of the De Moivre Formulas for Quaternions and Octonions; Math. Studies in the Honour of Luis de Albuquerque; Universidade de Coimbra: Coimbra, Portugal, 1994. [Google Scholar]
- Şentürk, T.D.; Ünal, Z. 3-Parameter Generalized Quaternions. Comput. Methods Funct. Theory 2022, 22, 575–608. [Google Scholar] [CrossRef] [Scilit]
- Schafer, R.D. An Introduction to Nonassociative Algebras; Academic Press: New York, NY, USA, 1966. [Google Scholar]
- Bektaş, Ö.; Yüce, S. De Moivre’s and Euler’s Formulas for the Matrices of Octonions. Proc. Natl. Acad. Sci. USA 2019, 89, 113–127. [Google Scholar] [CrossRef] [Scilit]
- Bektaş, Ö. Split-type octonion matrix. Math. Methods Appl. Sci. 2019, 42, 5215–5232. [Google Scholar] [CrossRef] [Scilit]
- Jafari, M. The Real Matrix Representations of Semi-Octonions. Anadolu Univ. J. Sci. Technol.-Theor. Sci. 2016, 4, 99–112. [Google Scholar] [CrossRef] [Scilit]

Disclaimer/Publisher’s Note: The statements, opinions and data contained in all publications are solely those of the individual author(s) and contributor(s) and not of MDPI and/or the editor(s). MDPI and/or the editor(s) disclaim responsibility for any injury to people or property resulting from any ideas, methods, instructions or products referred to in the content. |
© 2024 by the author. Licensee MDPI, Basel, Switzerland. This article is an open access article distributed under the terms and conditions of the Creative Commons Attribution (CC BY) license (https://creativecommons.org/licenses/by/4.0/).