


Abstract
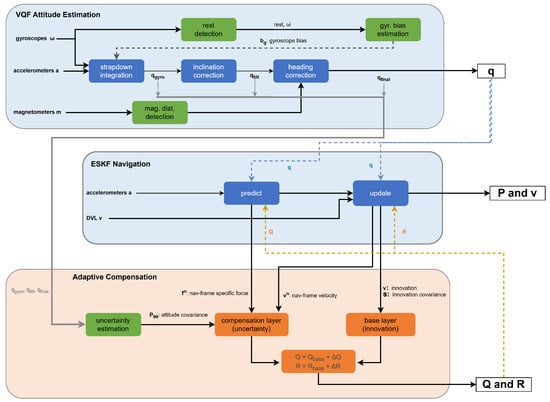
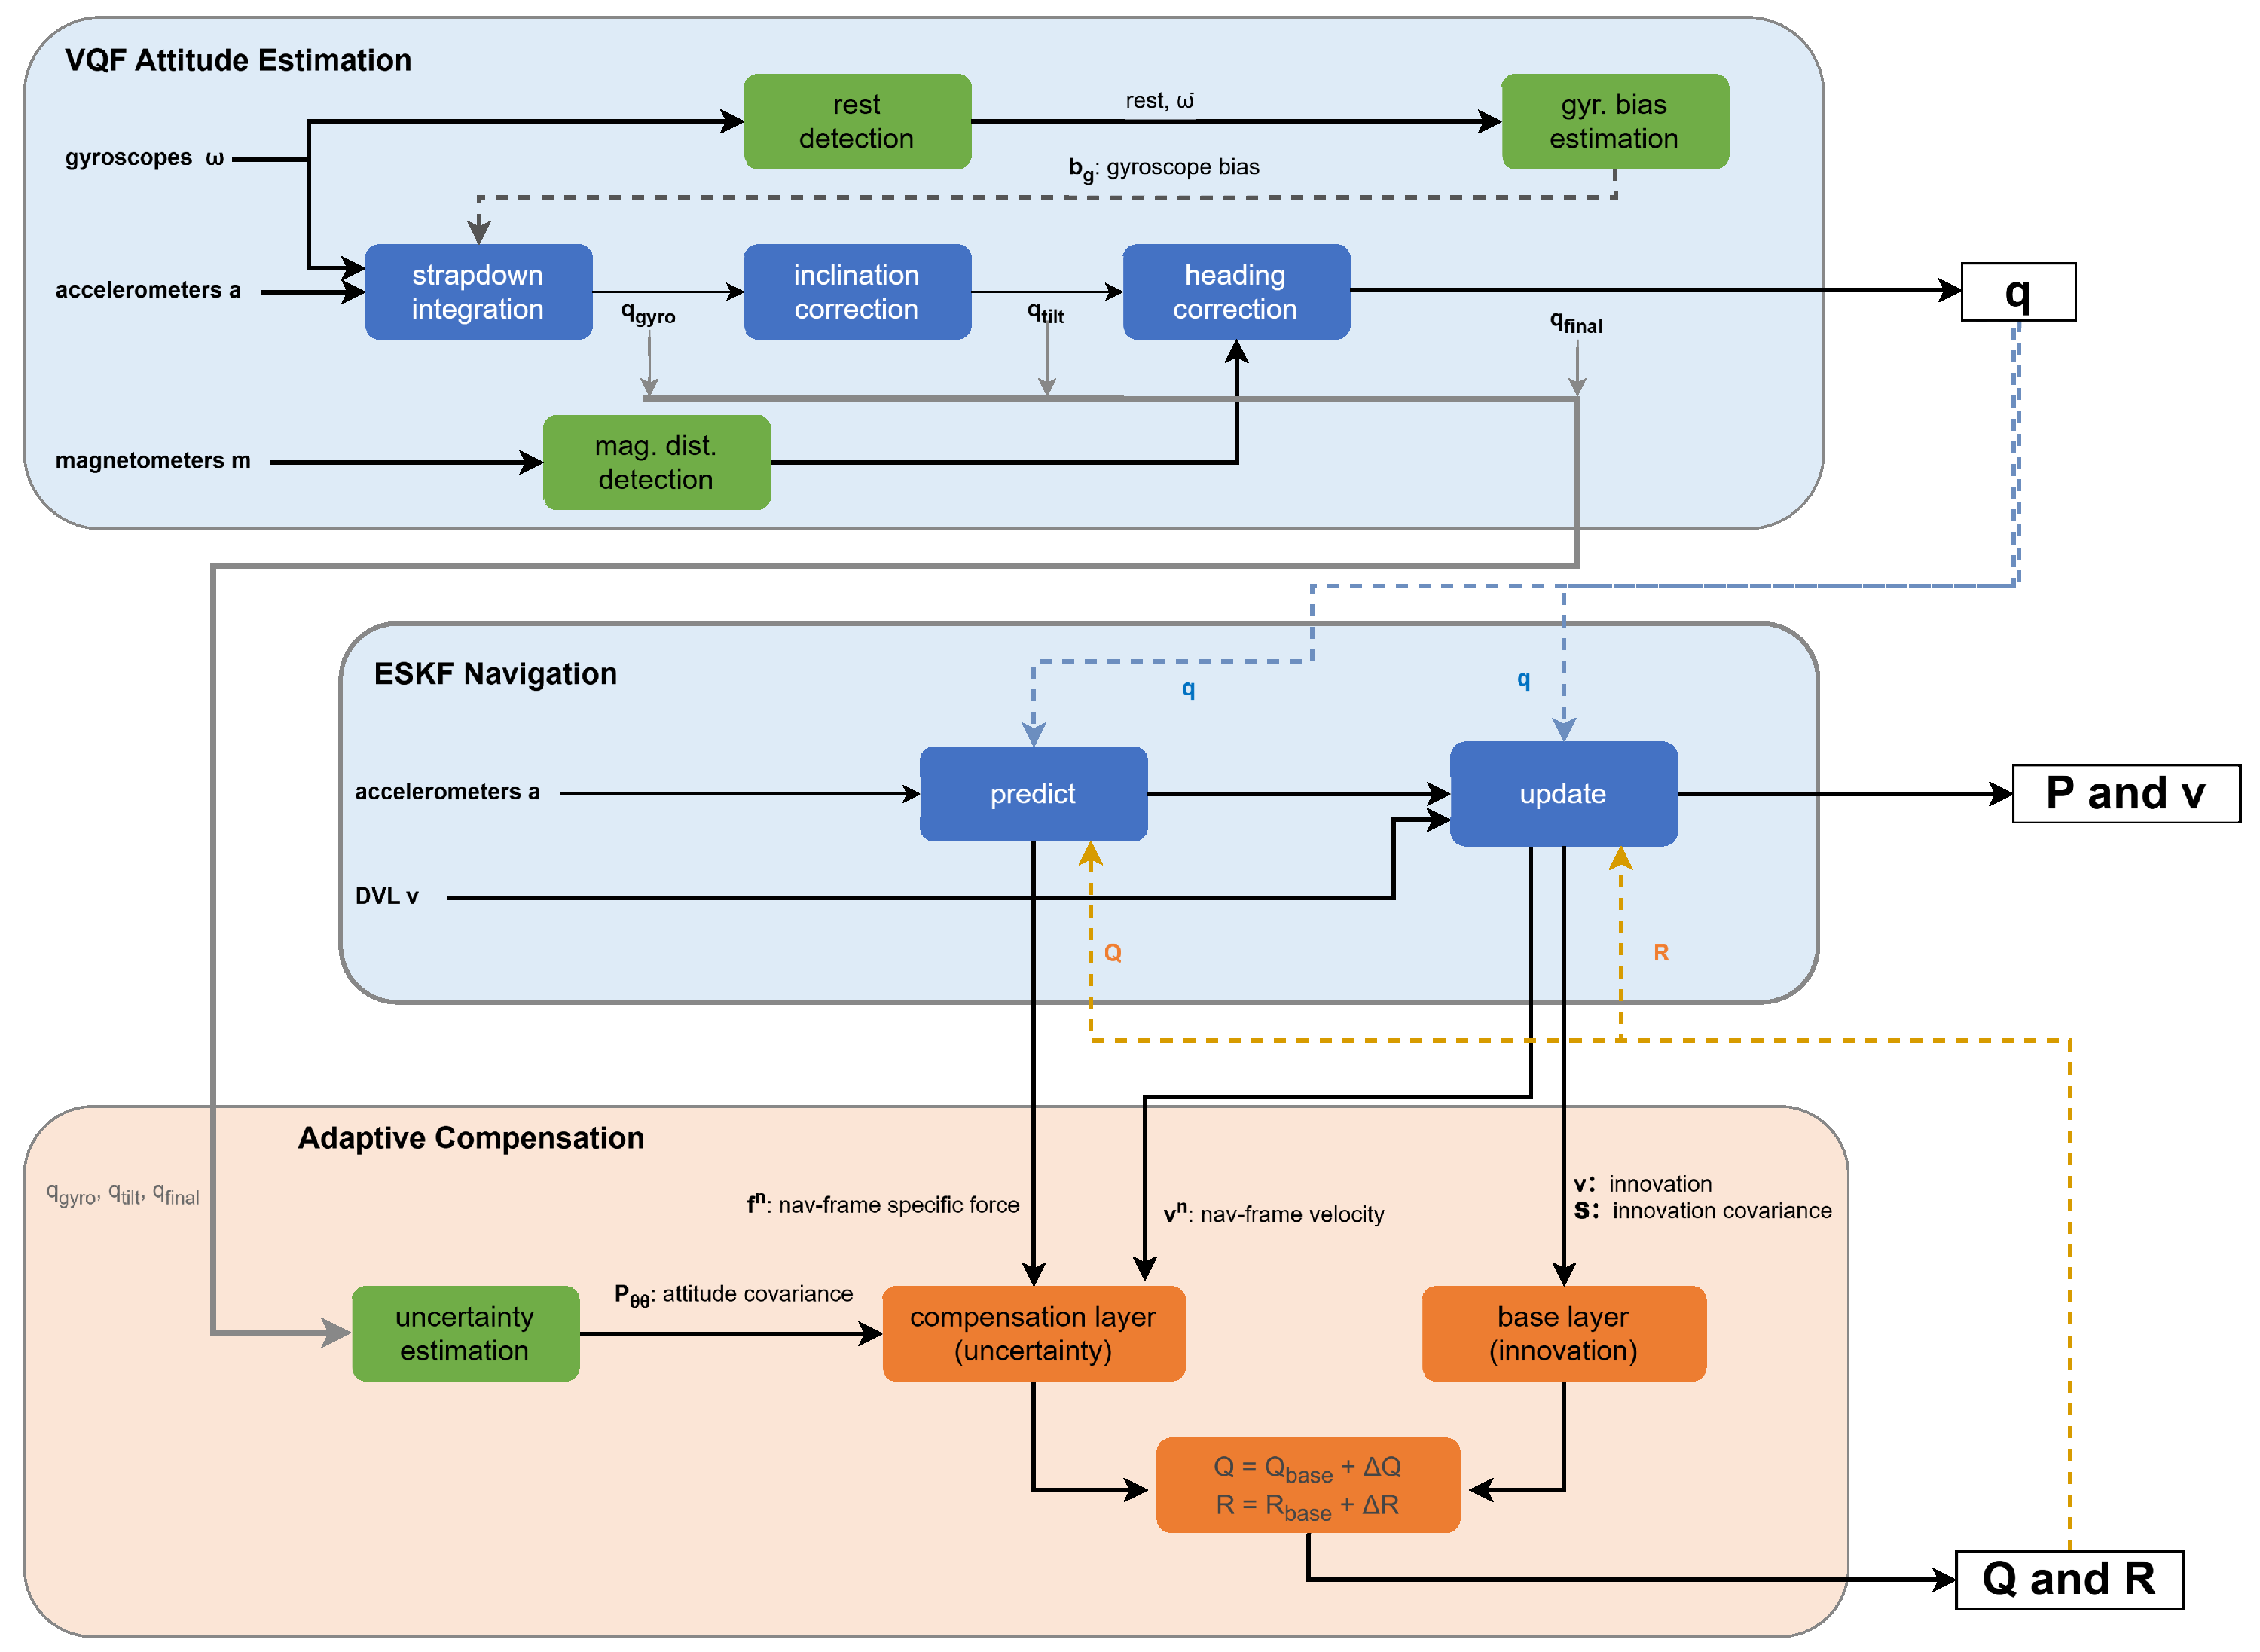
To mitigate the position divergence resulting from attitude error amplification in conventional fully coupled architectures, this study proposes a decoupled navigation architecture based on the Versatile Quaternion-based Filter (VQF). This architecture removes attitude estimation from the state vector, forming a two-layer structure comprising an independent attitude module and a navigation filter. The VQF is integrated as a standalone attitude module via a standardized interface. An uncertainty quantification model is developed by extracting the VQF’s internal correction states, which maps deviations among intermediate quaternion values to a measurable uncertainty metric. To compensate for the loss of cross-covariance induced by decoupling, a dual-layer compensation mechanism is introduced: a base layer adjusts the overall uncertainty using innovation statistics, while a compensation layer explicitly propagates attitude uncertainty through parameterized noise matrices. Experimental results demonstrate that the proposed method achieves notable improvements in positioning accuracy and significantly suppresses extreme errors in high-curvature scenarios. The approach is particularly effective for high-curvature, high-dynamic applications where process noise modeling is inherently difficult. Compared to traditional fully coupled architectures, the decoupled architecture offers enhanced robustness. The complementary characteristics identified between the two architectures provide valuable insights for expanding the operational envelope of underwater navigation systems.
1. Introduction
Autonomous underwater vehicles (AUVs) and remotely operated vehicles (ROVs) play increasingly critical roles in ocean resource exploration, underwater structure inspection, and seabed pipeline monitoring [1]. Modern underwater operations require vehicles to execute high-curvature and variable-curvature trajectories frequently. The spatial constraints and precision requirements of these missions render straight-line or large-radius cruising inadequate. Typical scenarios include: curved trajectory tracking during seabed pipeline inspection requires close adherence to pipeline contours [2]; structural inspection of offshore oil and gas platforms requires ROVs to circumnavigate cylindrical structures [3]; vehicles equipped with manipulators must approach targets along curved paths [4]. Typical torpedo-shaped AUVs face significant maneuvering constraints due to hydrodynamic characteristics and control surface limitations [5,6], with minimum turning radii often several times their body length.When operating in confined spaces or around complex structures, vehicles must execute high-curvature trajectories, posing considerable challenges for navigation system performance.
Underwater navigation technology faces severe environmental constraints: GPS signals cannot penetrate seawater [7], and acoustic positioning systems offer limited coverage at high cost [8]. The integration of inertial measurement units (IMUs) and Doppler velocity logs (DVLs), leveraging their autonomy and continuity, constitutes the foundation of underwater navigation systems [9]. IMU/DVL integrated navigation systems perform well during straight-line cruising but experience severe accuracy degradation when executing high-curvature trajectories. High-dynamic maneuvers generate significant centripetal acceleration, which contaminates accelerometer measurements of the gravity vector [10]. During high-curvature motion, the accelerometer measures both gravitational and dynamic accelerations simultaneously, degrading attitude estimation accuracy and subsequently affecting velocity and position solutions through coordinate transformation. The root cause of this phenomenon lies in the fully coupled architecture design of traditional navigation systems.
The Kalman filtering framework widely adopted in engineering practice unifies attitude, velocity, position, and sensor biases into a 15–16 dimensional state vector, forming a fully coupled system [11]. Within this structure, off-diagonal elements of the state transition matrix form coupling terms, causing attitude errors to affect velocity and position estimates through complex coupling relationships that become significantly amplified during high-curvature motion. According to classical inertial navigation error propagation theory [12], position errors induced by gyroscope bias exhibit quadratic growth with time during straight-line motion, whereas during curved motion, attitude errors couple to velocity estimates through centripetal acceleration, exhibiting cubic growth characteristics [13]. This implies that during a 10-min high-curvature mission, position error growth rates may exceed straight-line cruising rates by more than tenfold, severely constraining operational duration.
Researchers have proposed various solutions. Motion mode adaptive methods [14] optimize navigation performance through motion pattern recognition, yet these approaches face two core limitations: first, a fundamental contradiction exists between model library size and computational complexity—as the number of modes increases, real-time performance becomes increasingly difficult to guarantee; second, mode switching introduces delays that easily generate transient errors during rapid maneuvers, and coverage of unknown complex trajectories often proves inadequate. Parameter adaptive adjustment methods [15,16] respond to motion changes through dynamic adjustment of filter parameters, but noise covariance matrix estimation typically requires 5–10 min of convergence time. In high-dynamic scenarios, error growth rates far exceed parameter adjustment speeds, resulting in methods that enhance adaptability to environmental changes yet exhibit slow response and lack predictive capability. External constraint methods [17,18] demonstrate significant effectiveness in terrestrial navigation, benefiting from abundant prior information in terrestrial environments such as road networks and building elevations. However, underwater environments lack reliable prior information [19]: seafloor terrain maps possess low resolution, ocean currents cause dynamic environmental changes, and stable feature points are scarce, rendering constraint methods difficult to apply. These methods share a common limitation: they attempt to mitigate accuracy degradation through algorithmic optimization within traditional fully coupled architectures without fundamentally altering attitude error propagation paths.
Decomposing high-dimensional systems into independent subsystems can significantly improve navigation performance and fault tolerance [20]. Lyu et al. demonstrated in AUV integrated navigation systems that an adaptive federated filter architecture reduced position error by 66% compared to fully coupled approaches, validated through 30 experimental trials with SINS/DVL/TAN integration. This empirical evidence inspires a new improvement approach: extracting independent estimation modules from traditional fully coupled navigation systems to enhance estimation accuracy through reduced coupling complexity. Huang et al. [21] achieved partial decoupling by expanding quaternions into state variables, improving attitude estimation accuracy by in underwater glider applications. However, quaternions remained estimated quantities, attitude-velocity coupling terms persisted in the state transition matrix, and error amplification problems continued during high-curvature motion. Shaukat et al. [22] employed RBF neural networks as assistance, learning attitude error patterns to improve estimation, yet retained the full-state Kalman framework with neural networks serving as compensation rather than architectural reconstruction. The common limitation of these methods lies in attitude estimation remaining coupled with the navigation filter, unable to fundamentally block attitude error propagation to velocity and position through the state transition matrix.
Completely eliminating attitude-velocity coupling terms from state transition equations requires separating attitude estimation from the navigation filter and establishing an independent attitude estimation module. This requires attitude algorithms to possess three key characteristics: independent operation capability, high-precision output, and uncertainty quantification. The Versatile Quaternion-based Filter (VQF) by Laidig and Seel [23] provides an ideal solution for decoupled architectures. Compared to traditional attitude algorithms, VQF offers significant advantages: relative to EKF-AHRS, VQF eliminates the need for complex noise covariance matrix tuning and reduces computational complexity by approximately ; relative to complementary filters such as Madgwick and Mahony, VQF can output attitude uncertainty, providing crucial information for subsequent compensation mechanisms; VQF’s magnetic disturbance rejection capability renders it particularly suitable for underwater environments with ferromagnetic structures. VQF’s triple output satisfies the core requirements of decoupled architectures: attitude quaternions for coordinate transformations, relative acceleration for motion intensity perception and parameter adaptation, and attitude uncertainty for quantifying estimation reliability and compensating for covariance information loss caused by decoupling.
This study proposes a VQF-based decoupled navigation architecture that addresses accuracy degradation during high-curvature motion from both architectural and algorithmic perspectives. The main contributions of this research are as follows:
- 1.
- VQF-based attitude-navigation decoupling scheme: Attitude estimation is completely separated from the navigation filter state vector, with VQF serving as an independent attitude module. The attitude-velocity coupling term in the state transition matrix is eliminated, blocking deterministic error propagation under high-curvature conditions.
- 2.
- Uncertainty extraction method from VQF internal states: A method is proposed to quantify attitude uncertainty through statistical deviations among quaternions at different correction stages during VQF processing, providing explicit attitude reliability metrics for the decoupled architecture.
- 3.
- Dual-layer compensation mechanism for attitude uncertainty: A noise covariance adjustment strategy is designed that combines base-layer innovation adaptation with compensation-layer attitude uncertainty parameterization. Attitude uncertainty is mapped to process and observation noise increments through kinematic coupling relationships.
The remainder of this paper is organized as follows: Section 2 establishes the theoretical foundation, analyzes degradation of traditional architectures in specific scenarios, and reveals the necessity of decoupling; Section 3 details the conditions that decoupling must satisfy; Section 4 explains the specific decoupled system design; Section 5 validates method performance through real datasets; Section 6 summarizes the work and provides future research directions.
2. Error Propagation Mechanisms During High-Curvature Motion
Traditional fully coupled error-state extended Kalman filters (ESKFs) exhibit significant accuracy degradation during high-curvature maneuvers involving high angular velocity turns. This chapter analyzes the fundamental causes of this phenomenon—namely, the roles of the coupling term and the cross-covariance submatrix in propagating attitude errors and uncertainty to velocity errors—revealing the necessity of decoupling in such scenarios.
2.1. High-Curvature Motion and Coupling Term Error Amplification
We first clarify the terminology. In this work, high-curvature motion refers to maneuvering segments with curvature (turning radius m). This threshold encompasses typical underwater close-proximity operations where turning radii commonly range from 5 to 20 m, while excluding near-straight-line cruising. Under such conditions, the centripetal acceleration becomes significant. It is , rather than alone, that directly amplifies the coupling term ; therefore, we focus on centripetal acceleration as the primary physical quantity in error analysis. Throughout this paper, and g denote scalar magnitudes (in m/).
The state vector of a fully coupled IMU/DVL navigation system includes attitude, velocity, position, and biases:
where each component , and relates to quaternion error via . The error dynamics equation is [12]:
where denotes accelerometer noise, and represents the attitude-velocity coupling term, denotes its skew-symmetric matrix, reflecting the intensity of attitude error ’s influence on velocity error rate . During stable cruising, m/ remains relatively constant, resulting in a basically constant velocity error growth rate for a given attitude error, making error propagation characteristics predictable.
High-curvature motion generates centripetal acceleration , causing IMU measurements to include motion acceleration components. Taking horizontal circular motion as an example, based on the analysis by Borodacz and Szczepanski [13], the spectral norm of the coupling term satisfies:
More generally, high-curvature maneuvers cause to deviate significantly from the nominal value g, with the magnitude of increase related to centripetal acceleration.
This implies that the same attitude error produces a larger velocity error growth rate under high curvature, and that the error propagation path is amplified. Simultaneously, centripetal acceleration contaminates the accelerometer’s observation of the gravity direction [24], degrading attitude estimation accuracy itself and increasing the error source. Therefore, both increased attitude error sources and enhanced error coupling jointly lead to accumulated estimation errors in high-curvature scenarios.
2.2. Cross-Covariance Underestimation Mechanism
Beyond deterministic error propagation through , the Kalman filter relies on the cross-covariance to compute correction gains that compensate for attitude errors using DVL velocity observations. However, under high-curvature conditions, becomes systematically underestimated, causing the correction mechanism to fail progressively.
The attitude-velocity cross-covariance propagates according to:
Here, and represent the attitude and velocity self-transition submatrices, characterizing how each state evolves independently within a single time step. The coupling submatrix quantifies attitude-to-velocity error propagation, as analyzed in Section 2.1. The reverse coupling vanishes identically because velocity does not appear in attitude kinematics—this asymmetry is precisely what enables attitude to be estimated independently of velocity errors in the decoupled architecture proposed herein.
The process noise terms capture stochastic uncertainty: represents attitude process noise arising from gyroscope angular random walk, while since gyroscope and accelerometer noise sources are statistically independent. Under first-order approximations (, ), the propagation simplifies to:
This result reveals that growth depends on two factors: as the uncertainty source, and as the amplification coefficient. Since increments by at each prediction step, underestimation of propagates directly to , with the effect amplified by .
Under high-curvature conditions, actual process noise increases substantially due to model violations (centripetal acceleration invalidates quasi-static assumptions), linearization errors (large attitude rates), and unmodeled dynamics (sideslip effects). The Q matrix, typically tuned for nominal straight-line conditions, cannot adapt in real-time [15], causing systematic underestimation of . This underestimation originates fundamentally from observability dimension mismatch during EKF linearization [25], whereby the filter extracts spurious information from unobservable directions. Combined with the amplified established in Section 2.1, the underestimation propagates from to with increasing severity, ultimately distorting the Kalman gain used for attitude correction.
2.3. Correction Failure and Adverse Cycles
During DVL observation updates, Kalman filtering uses velocity residuals to correct states. Fully coupled architectures utilize velocity information for attitude correction through the cross-covariance :
Undersized correction gains result in insufficient attitude correction. Residual attitude errors easily form prediction-update cycles, leading to cumulative error trends. For maneuvering AUVs, certain attitude error states (such as down-tilt misalignment angles) couple with gyroscope biases in the unobservable subspace [26]. When becomes distorted, the correction of these error states becomes further constrained.
Fully coupled architectures face three problems in high-curvature scenarios: high curvature increases , high dynamics make accurate Q modeling difficult, and the fully coupled architecture amplifies distortion. Within the coupling mechanism, the coupling term amplifies error propagation, while the cross-correction that should be achieved through fails due to covariance distortion, with negative effects dominating. Under these circumstances, decoupling attitude from the state vector trades coupling benefits for system robustness, suppressing error drift during high-curvature motion.
5. Experiment
This chapter validates the theoretical analysis and algorithmic design presented in previous chapters through real-world IMU/DVL integrated navigation data.
5.1. Experimental Data and Analysis Strategy
The experimental dataset comprises authentic IMU/DVL measurements collected from the Danjiangkou Reservoir area in China. The trajectory spans 391.951 m over approximately 650 s and includes multiple curved turning segments with maximum curvature of approximately (corresponding to a turning radius of approximately 4 m) and average velocity of approximately . The AUV platform is equipped with an inertial navigation system and auxiliary sensors, whose primary performance specifications are summarized in Table 2.
Table 2.
Sensor specifications.
The trajectory encompasses high-curvature maneuvering scenarios emphasized in the theoretical analysis, contrasting with conventional straight-line or regular grid paths. It represents typical scenarios where traditional navigation algorithms encounter challenges. The dataset covers a broad range of operating conditions: velocity varies from 0.3 to 0.9 m/s, curvature ranges from 0.04 to 0.28 , and the resulting centripetal acceleration spans approximately 0.01 to 0.22 m/. To demonstrate performance variations under different conditions, the trajectory is manually partitioned into four representative segments based on curvature characteristics for comparative analysis.
Since GPS signals are unavailable underwater, high-precision ground truth is obtained by conducting experiments in shallow water. A GPS antenna is mounted at an elevated position on the vehicle body to ensure continuous GPS signal reception while IMU and DVL operate normally, with the platform navigating at depths of 0.5–2 m. The reference trajectory generation procedure follows these steps:
- 1.
- RTKLib (version 2.4.3, developed by the RTKLIB Development Team, Tokyo, Japan) performs differential post-processing on raw GPS observations to obtain centimeter-level positioning results.
- 2.
- The final reference trajectory is generated through RTS smoothing, combining high-frequency IMU attitude and DVL velocity information.
Closure error assessment from round-trip segments indicates that the reference trajectory exhibits cumulative position error of approximately 0.8 m (closure error rate of 0.2%), meeting the precision requirements for algorithm performance evaluation.
The VQF-EKF configuration is specified in Table 3.
Table 3.
VQF-EKF parameter configuration.
The AEKF baseline algorithm employs a 16-dimensional error-state filter architecture with parameters configured according to standard underwater navigation settings [28], including IMU noise parameters derived from Allan variance analysis, DVL measurement noise, and innovation-based adaptive strategy (window length of 50 DVL observations, adaptive factor range ). This configuration has been fine-tuned on the experimental trajectory to ensure convergence stability.
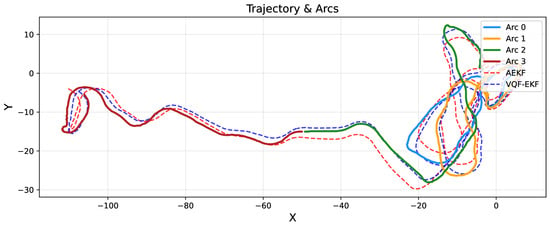
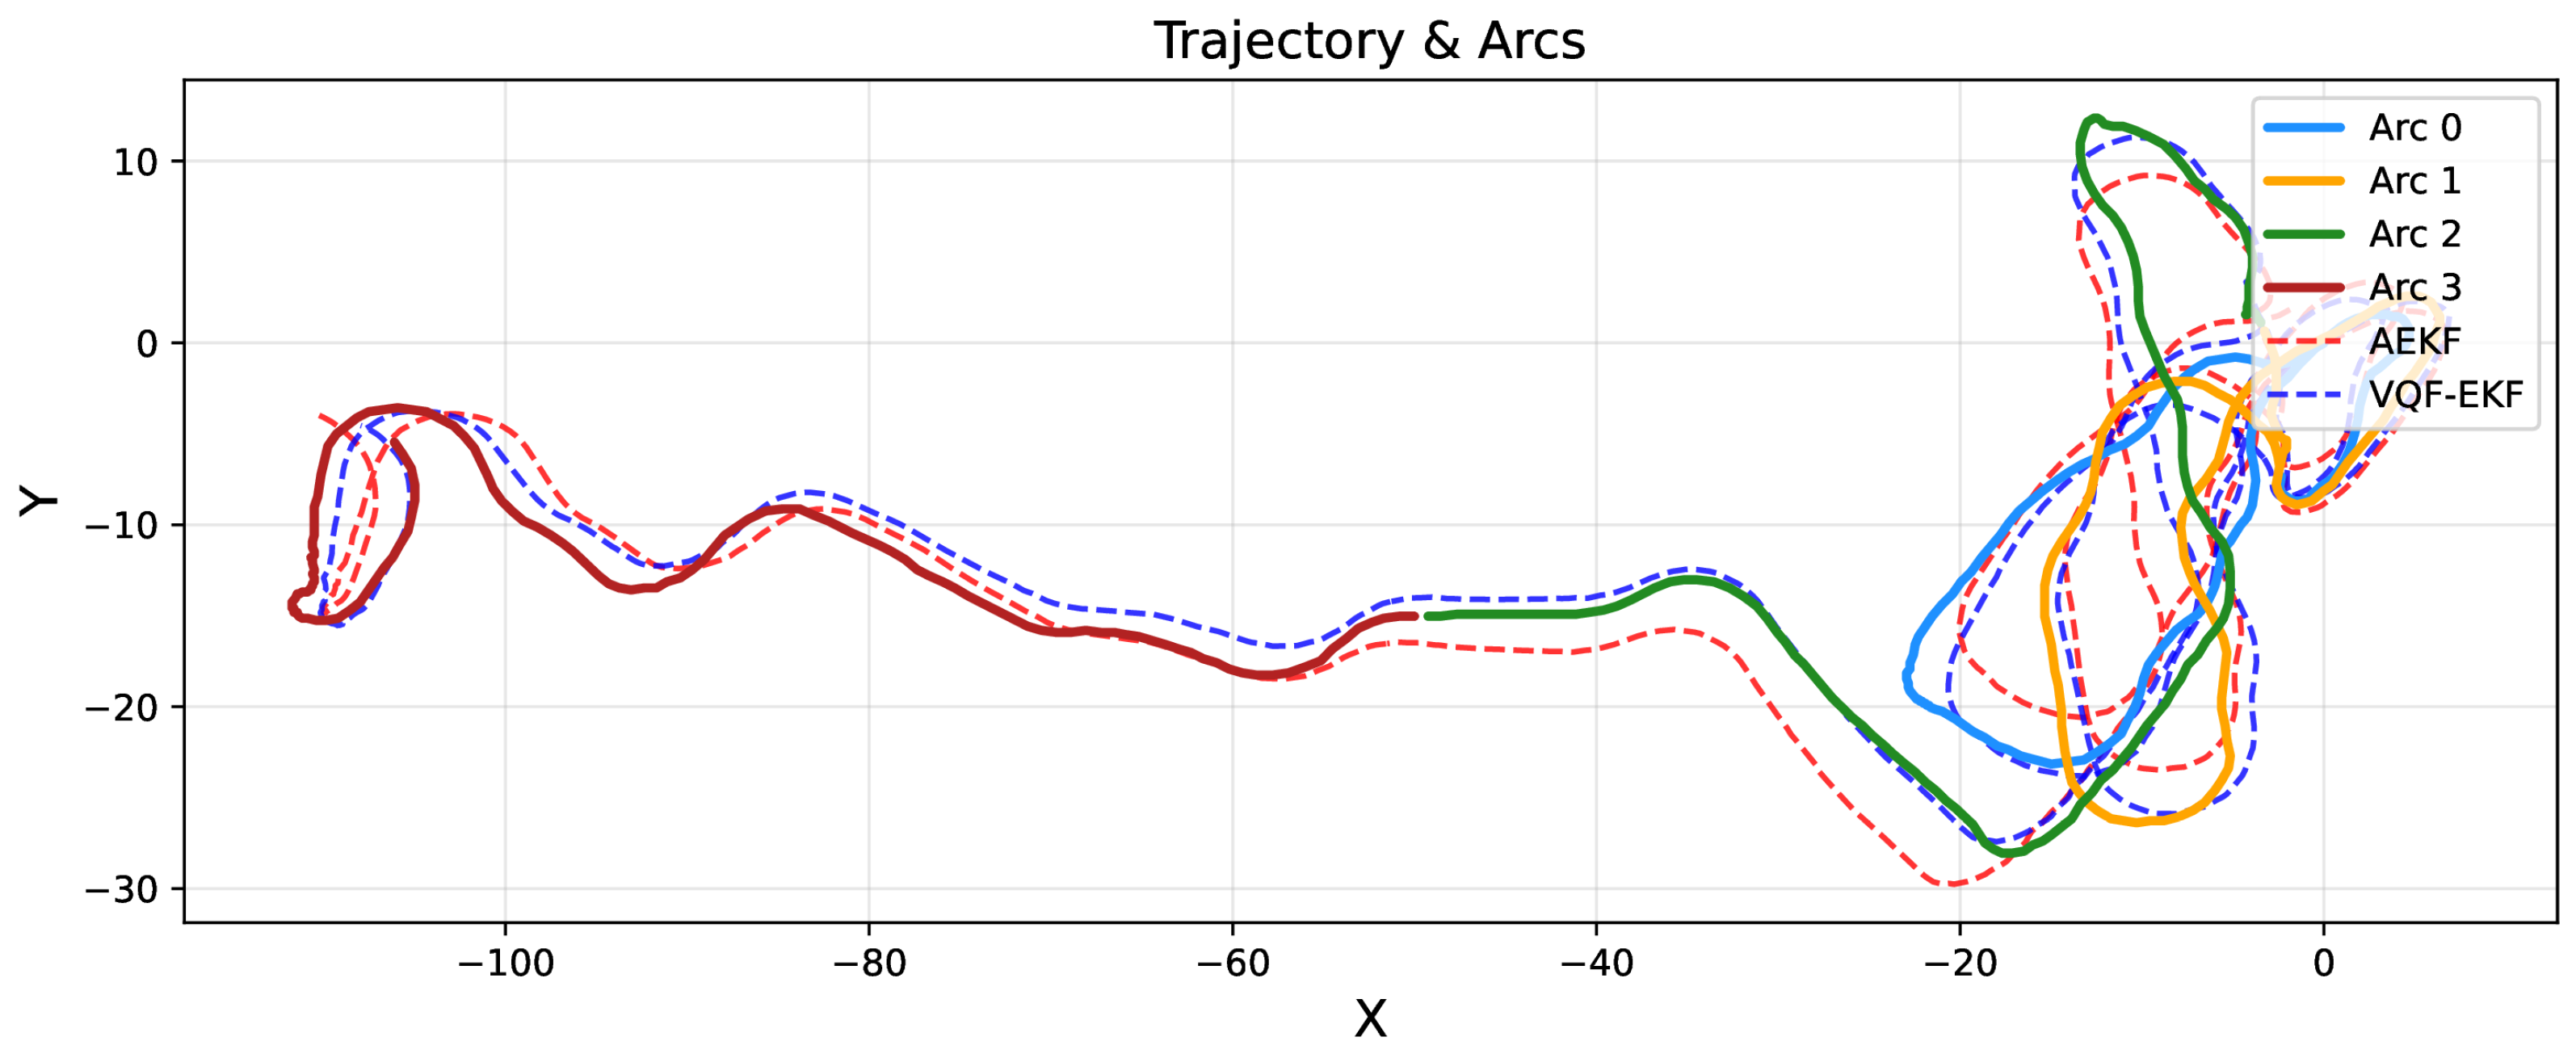
Figure 2 presents the overall trajectory layout and segmentation results. Solid lines represent ground truth trajectories, while dashed lines denote estimated trajectories (red for AEKF, blue for VQF-EKF). The four analysis segments are marked with distinct colors. In the high-curvature Segment 2 region (the circular segment on the right side of the trajectory), AEKF exhibits significant deviation from ground truth, whereas VQF maintains excellent tracking performance, intuitively validating the advantages of the decoupled architecture in high-curvature scenarios.
Figure 2.
Trajectory comparison.
5.2. Performance Metrics
This study employs the following evaluation metrics:
Root mean square error (RMSE) serves as the primary accuracy indicator. To characterize turning segment performance, particular emphasis is placed on analyzing normal error (deviation perpendicular to the path tangent direction):
where denotes the trajectory normal unit vector. According to the analysis in Section 2.1, normal error directly reflects the influence of velocity estimation under high-curvature motion, resulting in lateral deviation, and constitutes a critical metric for evaluating high-curvature segment performance.
Improvement percentage is defined as:
Additionally, the P95 percentile assesses extreme error control capability, while the normal energy ratio:
which quantifies error directional distribution characteristics. Statistical significance is verified through three methods: paired t-test, Wilcoxon signed-rank test, and Bootstrap resampling (1000 iterations, 95% confidence interval).
5.3. Full-Trajectory Performance Analysis
Table 4 summarizes the comparative results of the two technical approaches on full-trajectory performance metrics.
Table 4.
Full-trajectory performance indicators.
VQF-EKF achieves 27.52% improvement in normal RMSE (2.30 m → 1.67 m) and 21.83% improvement in position RMSE (3.12 m → 2.44 m), validating the effectiveness of the decoupled architecture in eliminating attitude–velocity coupling and avoiding lateral deviation accumulation caused by attitude errors.
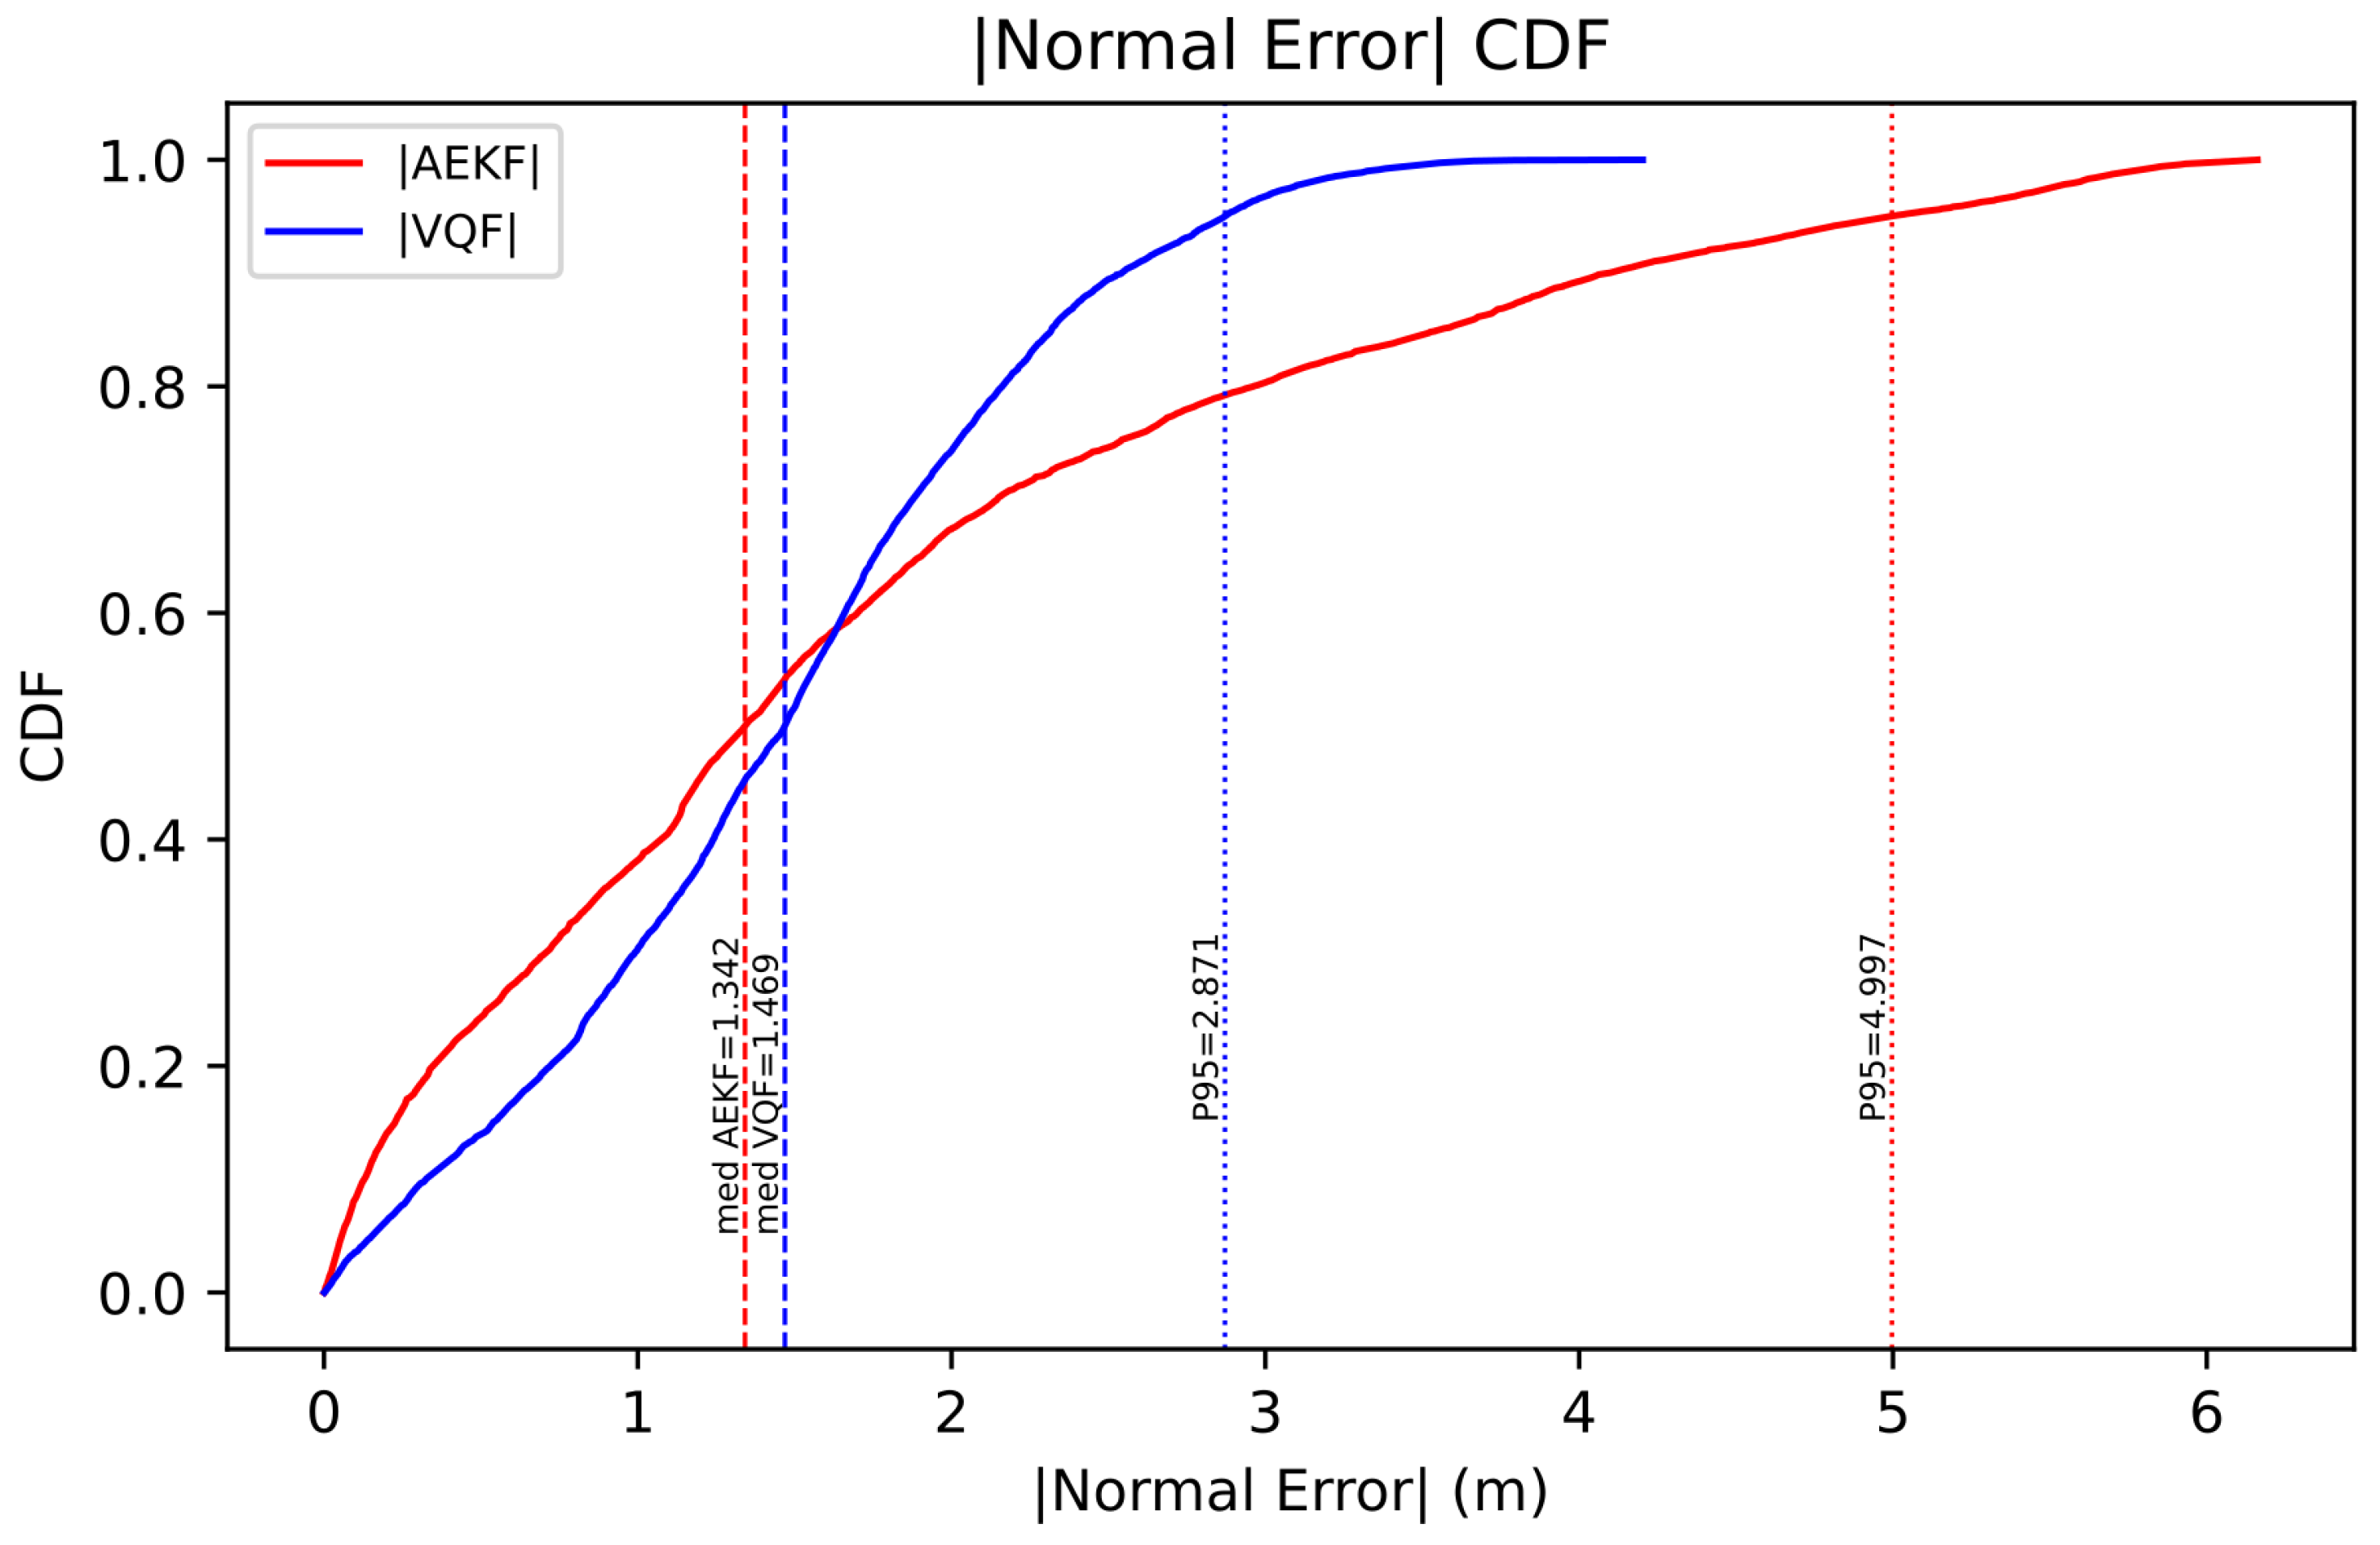
More significantly, P95 extreme error is substantially compressed by 42.55% (5.0 m → 2.9 m), demonstrating a “peak-suppression” characteristic: the decoupled architecture effectively suppresses error spikes during turning segments. Notably, the normal error median experiences a slight increase of 9.47%, but for safety-critical underwater navigation applications, controlling large errors (>5 m) that may lead to collisions is more critical than optimizing moderate errors, making this tradeoff a reasonable design choice. The 14.02% reduction in normal energy ratio indicates that the adaptive mechanism yields a more balanced error distribution.
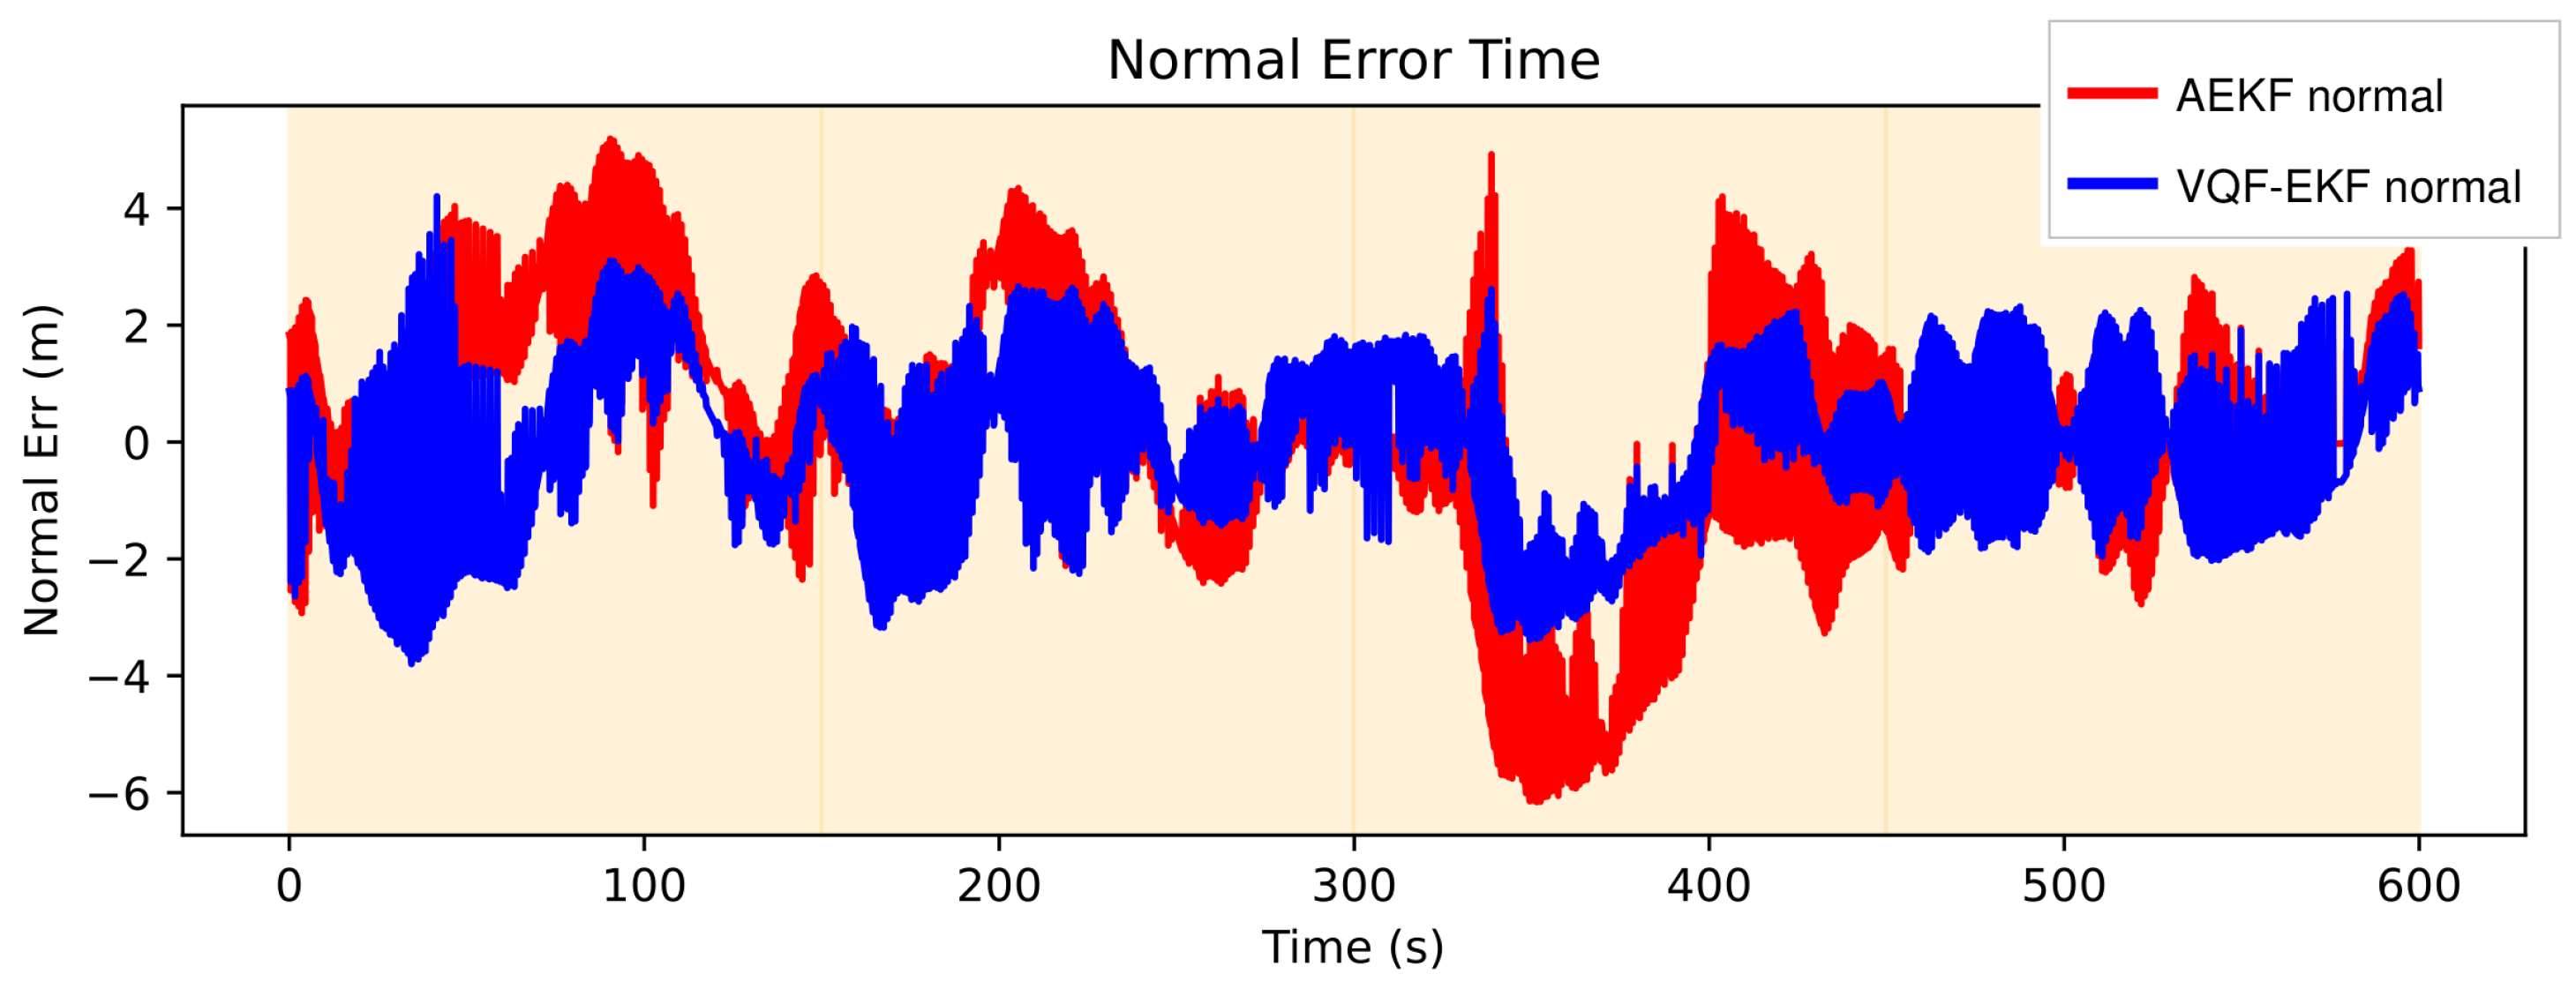
Figure 3 illustrates the temporal evolution of normal errors for both algorithms. The VQF-EKF system (blue) not only exhibits a narrower error envelope but, more importantly, avoids AEKF’s loss of control at critical moments. For instance, during the 350–400 s interval, AEKF experiences severe deviation of m, which VQF constrains within m. Improvement is particularly pronounced in the turn-intensive regions near 100 and 300 s, suggesting that algorithmic advantages correlate with motion complexity, consistent with the theoretical analysis in Section 2 regarding error accumulation during high-curvature segments.
Figure 3.
Normal error time series.
Given that this experiment is based on a single trajectory, the following methods are employed to assess improvement stability:
- 1.
- Time series paired test: Treating the N time instants of the single trajectory as N paired observations (AEKF error versus VQF error), paired t-test, and Wilcoxon signed-rank test are conducted. It should be noted that this method assumes independence of time series points, but temporal autocorrelation exists in practice; therefore, p-values serve only as reference indicators. Test results yield .
- 2.
- Bootstrap confidence interval: Block Bootstrap is performed on the trajectory time series (block size = 30 s to preserve temporal correlation), with 1000 resampling iterations. The 95% confidence interval for improvement is , remaining consistently distant from zero, indicating that improvement maintains a consistent direction across different sampling subsets.
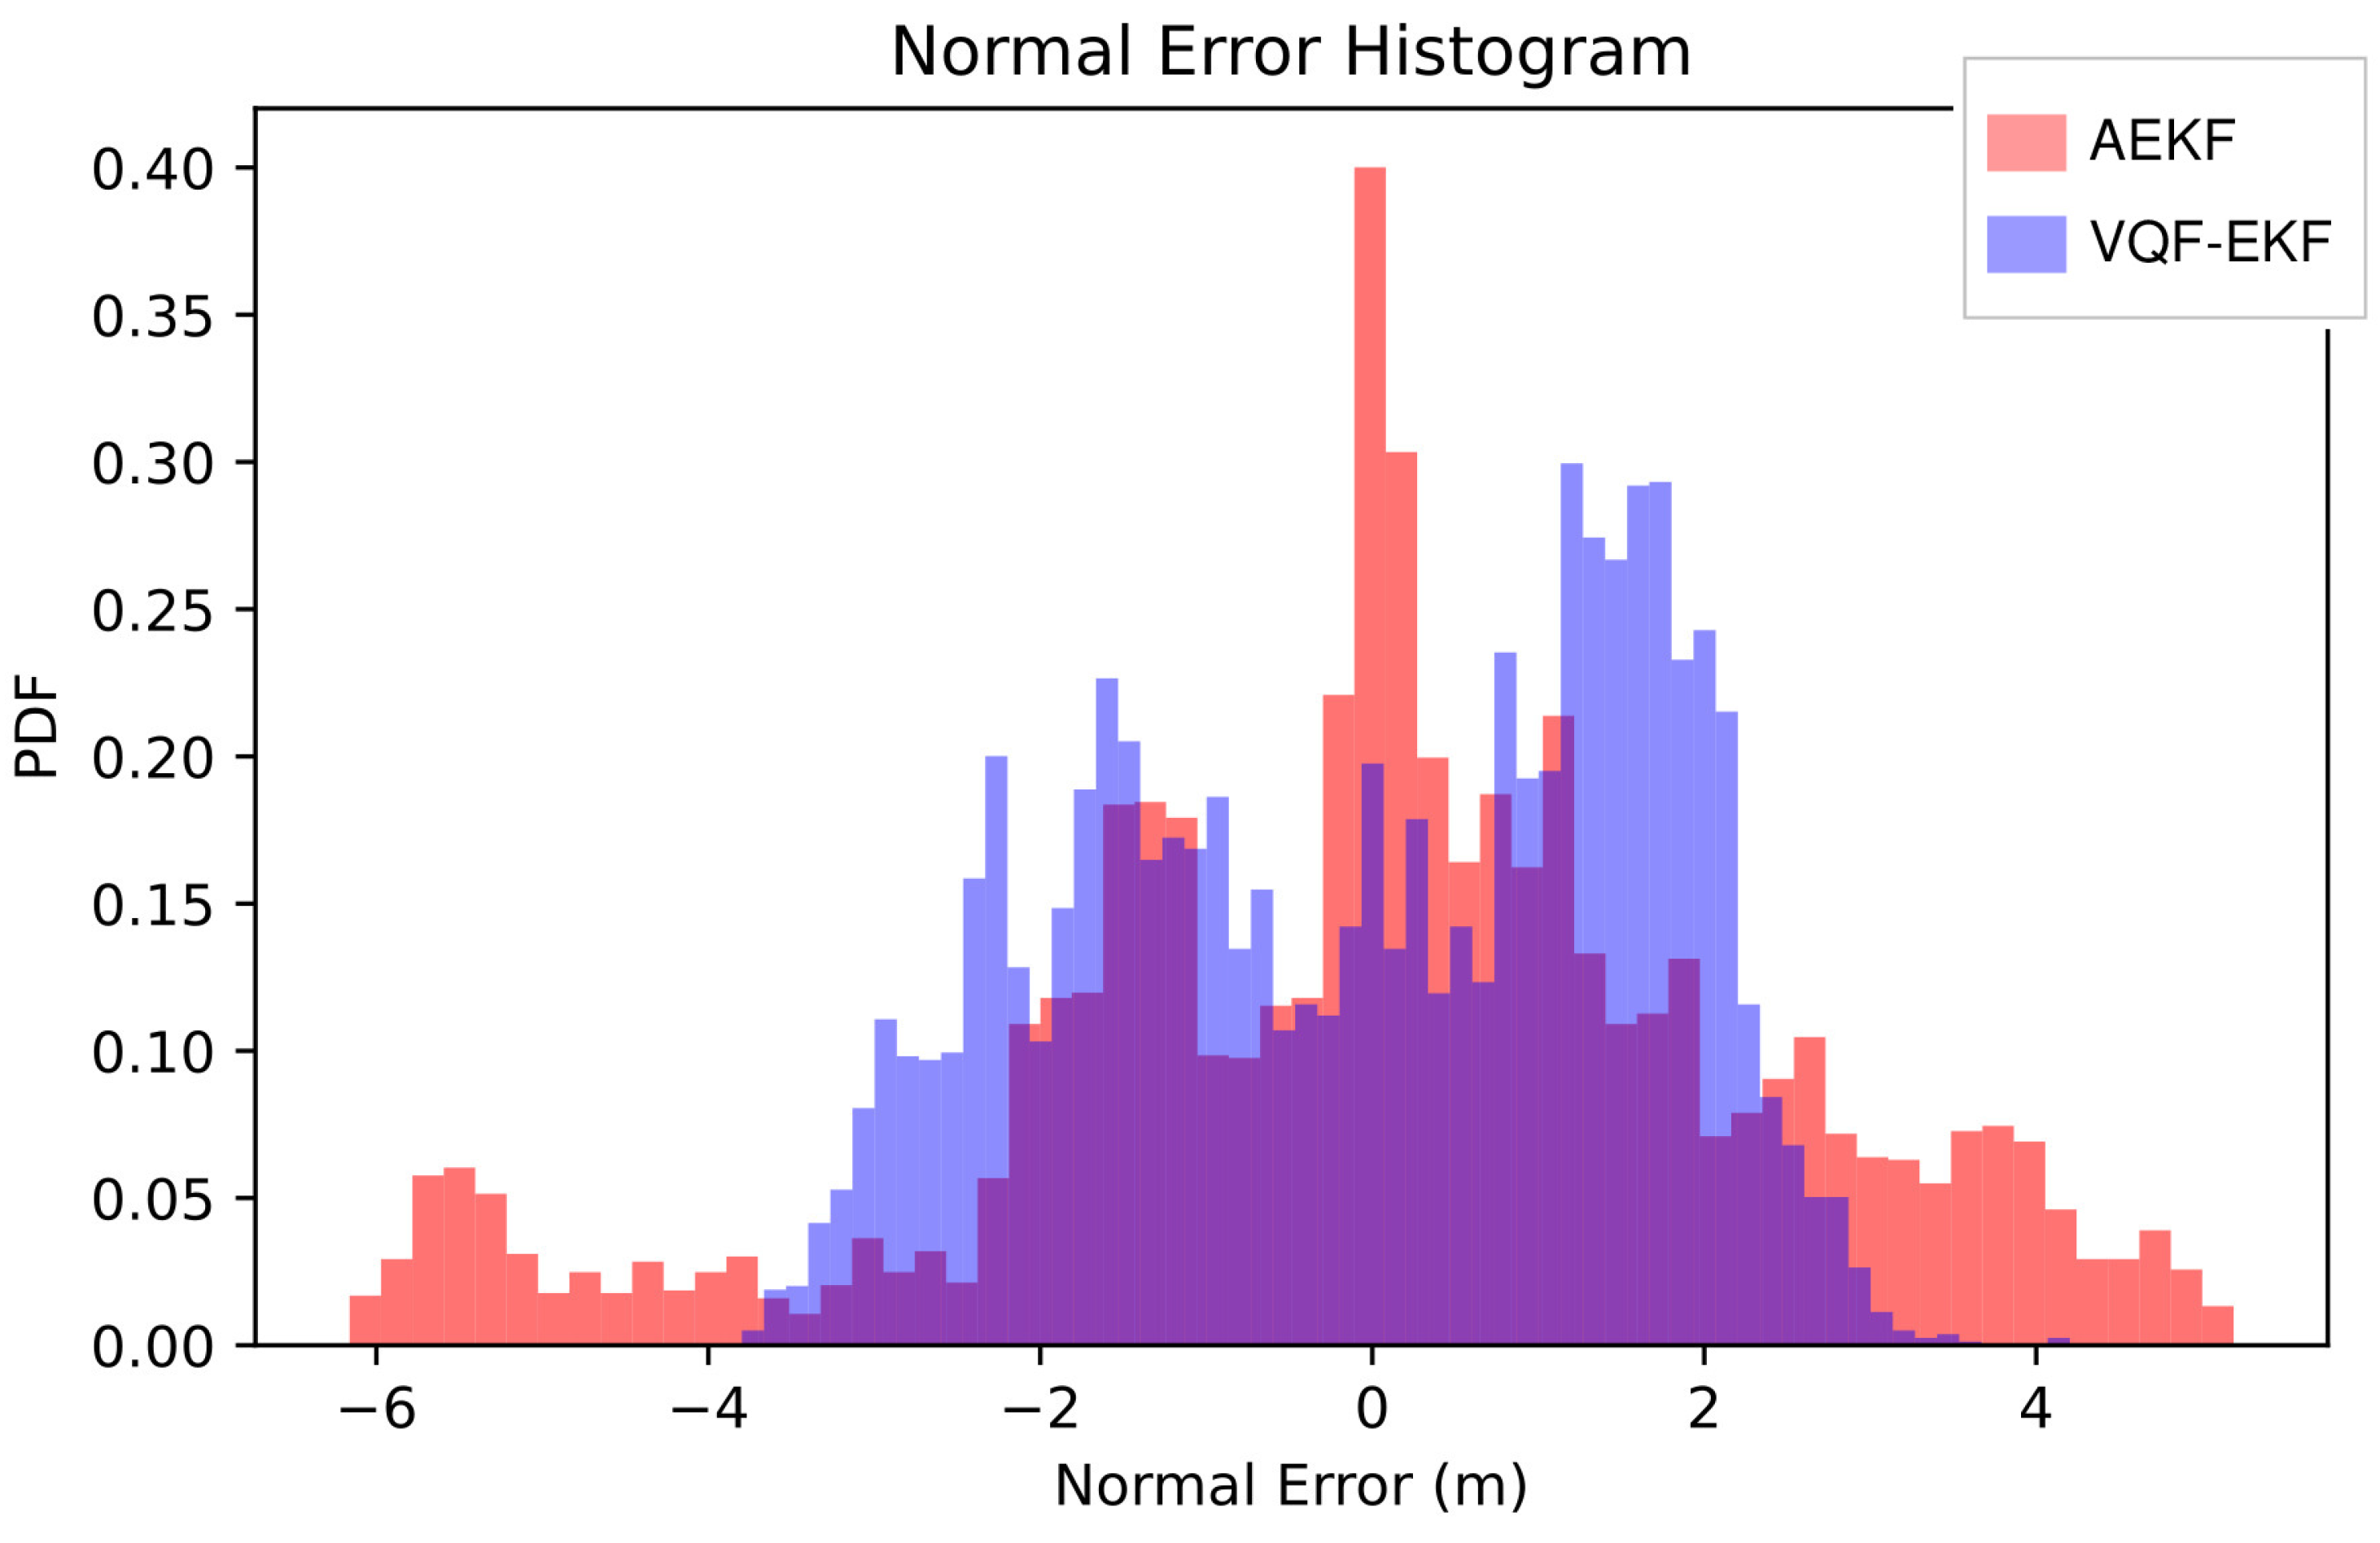
Figure 4 and Figure 5 further demonstrate the aforementioned improvement characteristics from a distributional perspective. The histogram reveals that improvement concentrates in the high tail, with AEKF exhibiting a “heavy-tail” morphology while VQF significantly reduces frequency. The cumulative distribution function shows that the VQF curve consistently lies above the AEKF curve. The distributional morphology confirms that improvement derives from tail compression rather than overall shift, embodying a reliability-oriented optimization strategy.
Figure 4.
Normal error histogram.
Figure 5.
Normal error cumulative distribution function.
5.4. Segment-Level Performance Analysis
Table 5 presents curvature statistics for each segment. It should be noted that the segmentation methodology was determined prior to execution and was not adjusted based on algorithm performance.
Table 5.
Curvature characteristics of each segment.
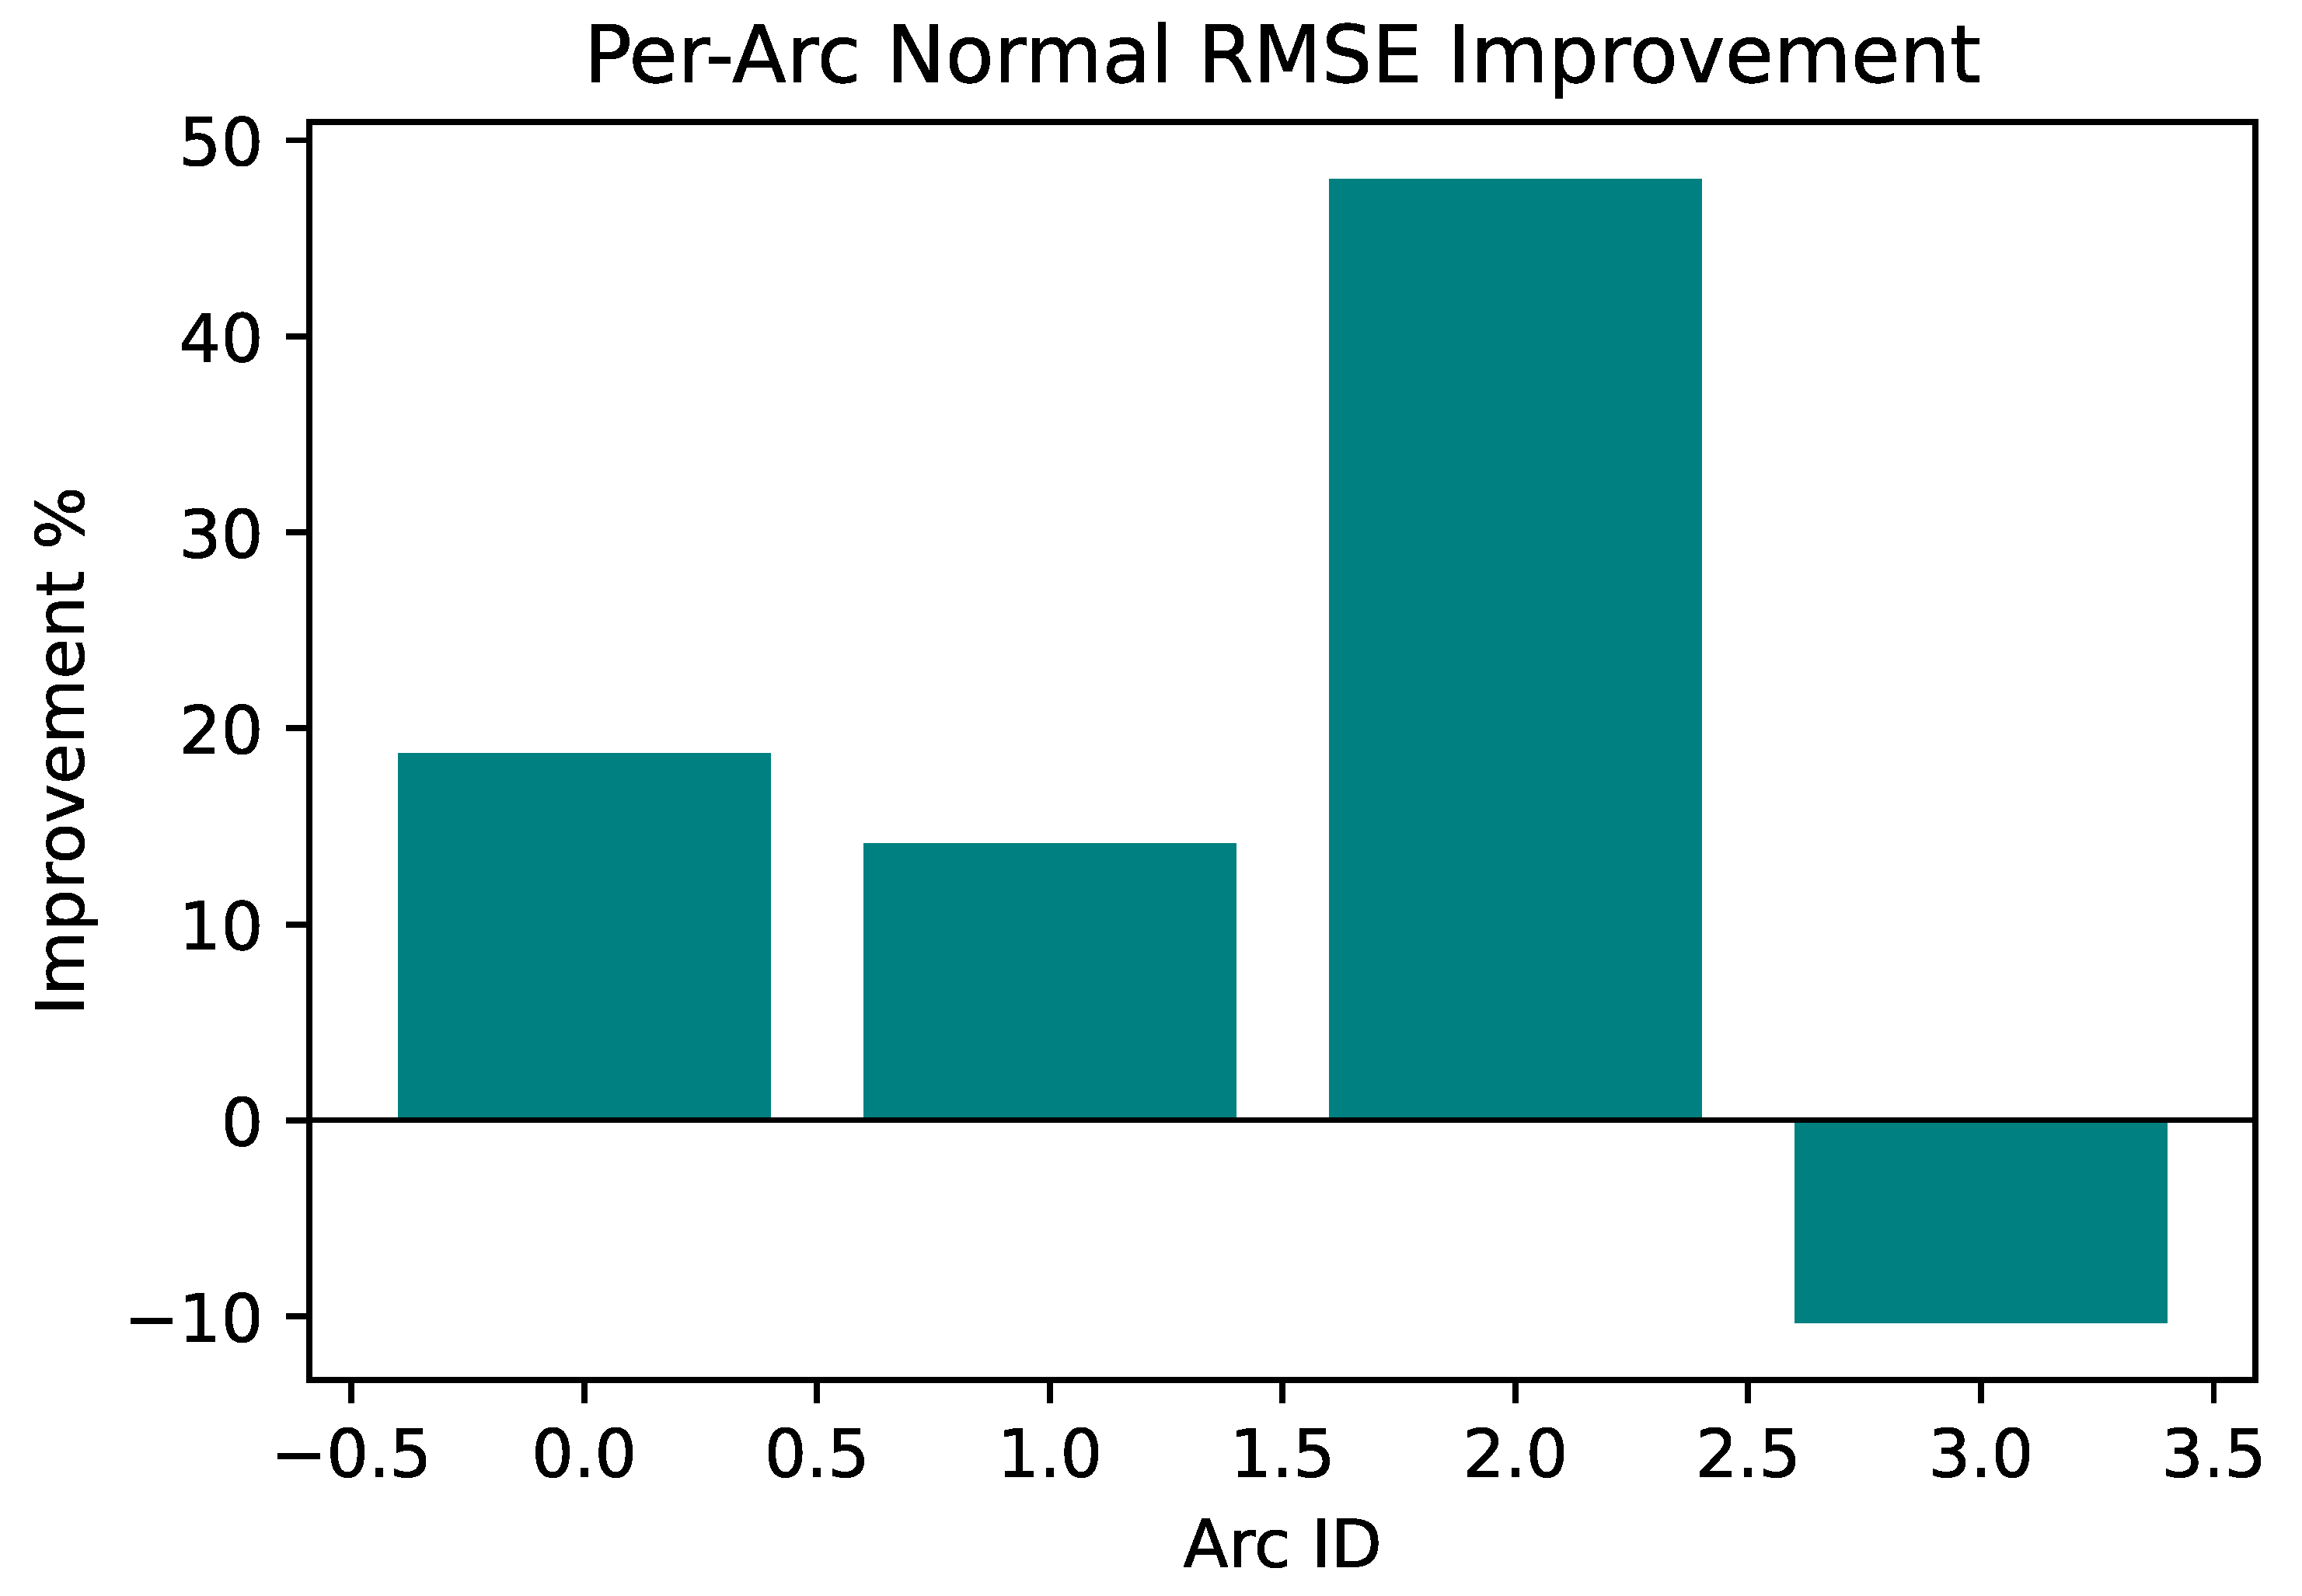
To quantitatively assess the spatial distribution characteristics of improvement, Figure 6 and Table 6 present performance comparisons for each segment.
Figure 6.
Segment improvement percentage bar chart.
Table 6.
Detailed performance indicators of each segment.
Results demonstrate significant spatial heterogeneity in improvement. Segment 2 (high-curvature segment) achieves 48.02% improvement, substantially exceeding the 18.72% and 14.13% improvements in Segment 0 and Segment 1. From an absolute error perspective, the high-curvature segment decreases from 3.2487 m to 1.6886 m, yielding an absolute improvement of 1.560 m, constituting the primary contribution source to global improvement.
Segment 3 exhibits a 10.33% relative degradation (absolute error 0.14 m) in the straight-line segment. This represents an architectural tradeoff: under low curvature, VQF’s unidirectional information flow lacks DVL reverse correction, whereas AEKF achieves more robust bidirectional feedback through coupling terms; simultaneously, system parameters are optimized for high-curvature scenarios. This tradeoff is reasonable: sacrificing 0.14 m in a low-risk scenario (baseline 1.34 m) in exchange for 1.56 m improvement in a high-risk scenario (baseline 3.25 m) yields an absolute improvement ratio of 11:1. Despite the relative degradation in this segment, the absolute error (1.48 m) still meets application requirements.
Segment-level analysis reveals the core advantages of the VQF-EKF architecture: achieving maximum improvement in high-curvature, high-error scenarios, effectively reducing navigation risk, and maintaining stability in scenarios already performing well. This differentiated improvement characteristic aligns with practical navigation reliability requirements.
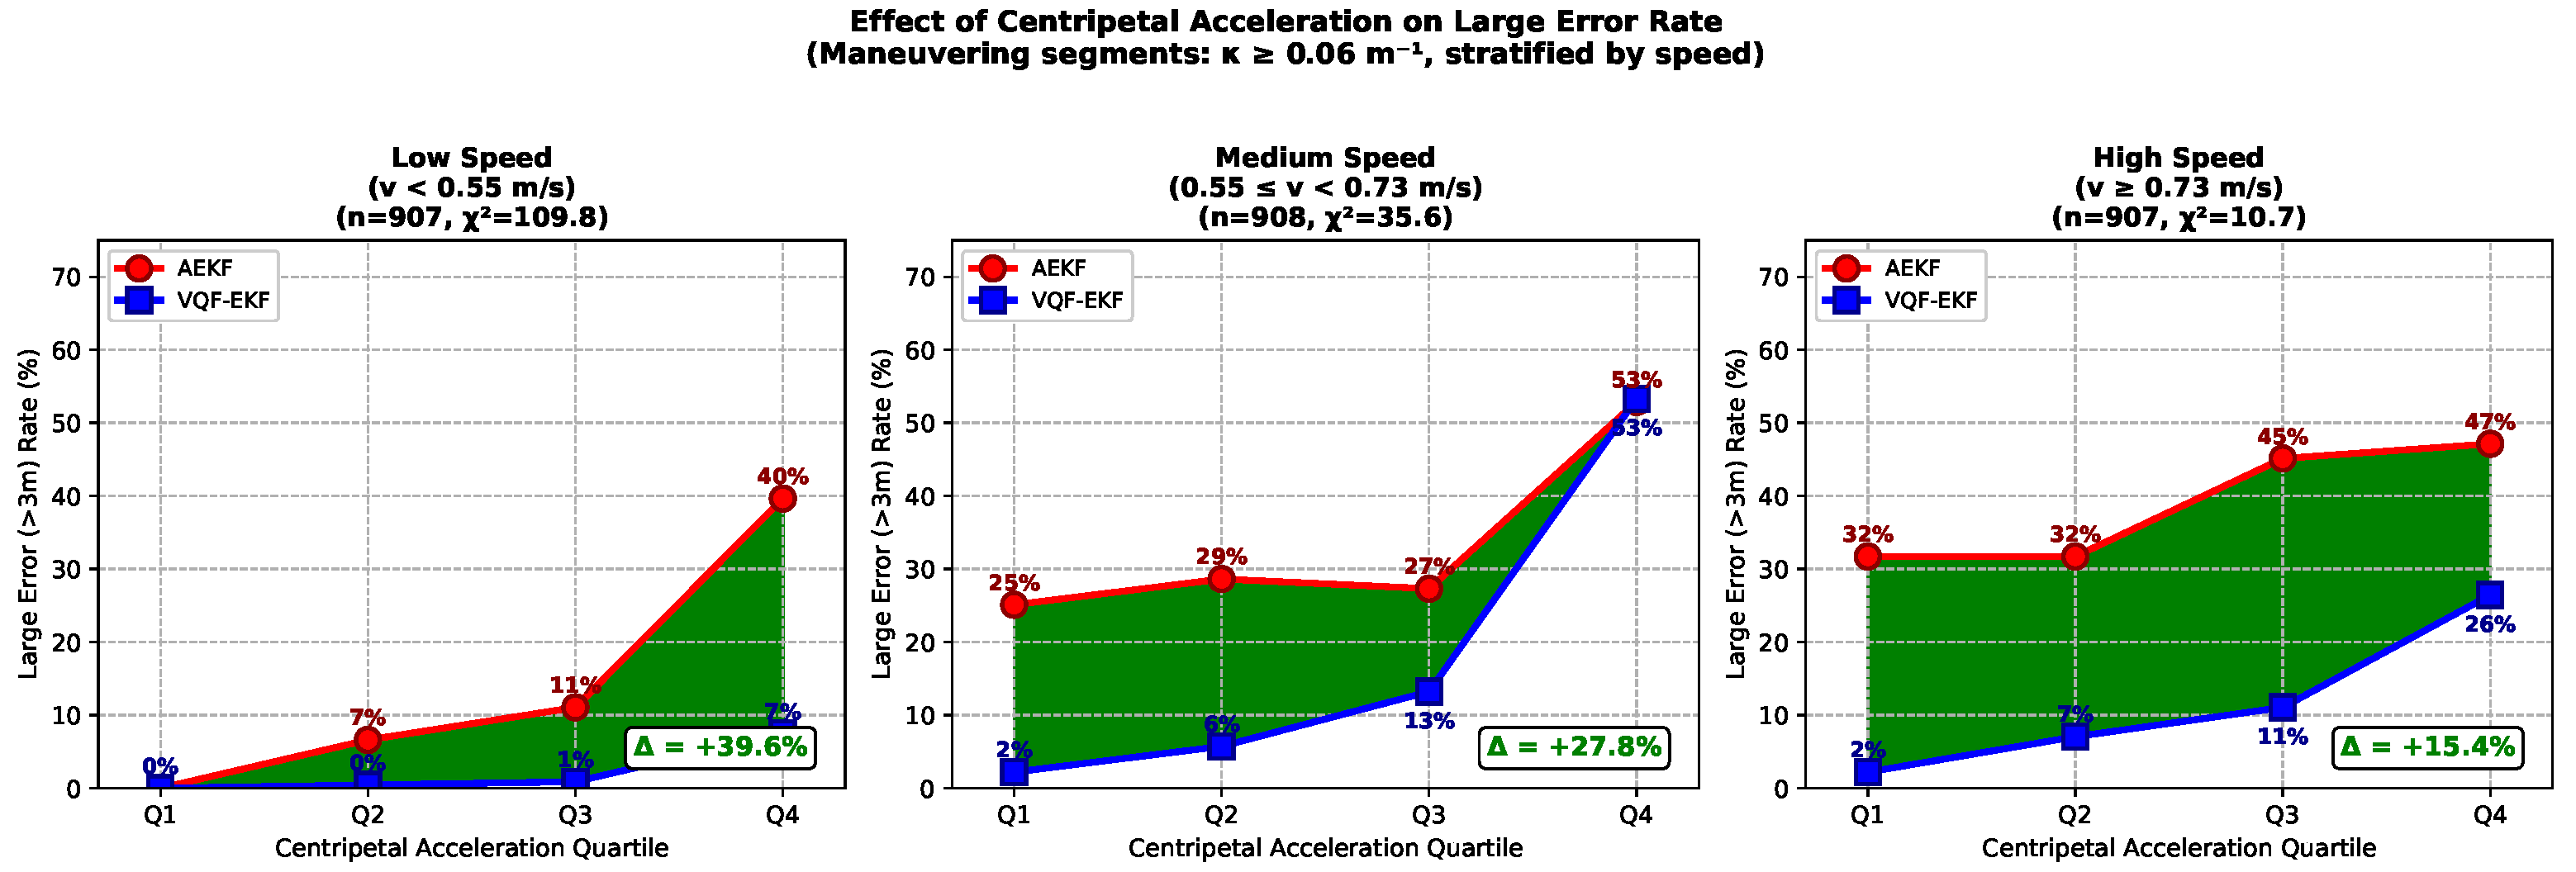
To provide statistical evidence for the theoretical prediction in Section 2.1 that centripetal acceleration amplifies coupling errors, we conducted a stratified analysis focusing on maneuvering segments ( , corresponding to turning radius m). Since centripetal acceleration depends on both velocity and curvature, we stratified the data by velocity to isolate the effect of .
Traditional metrics such as RMSE characterize average performance but may obscure tail behavior. For safety-critical underwater navigation, a single large error can lead to collision or mission failure, making the probability of extreme events more operationally relevant than mean error. We therefore adopt the large error occurrence rate—the proportion of samples exceeding a specified threshold—as a complementary metric that emphasizes tail-risk behavior. The 3 m threshold is selected based on operational requirements: typical torpedo-shaped AUVs have body lengths of 2–5 m, and position errors exceeding this scale pose significant collision risks in confined underwater environments such as pipeline corridors or offshore platform structures [2,3]. Furthermore, this threshold approximates the minimum turning radius in high-curvature maneuvers (approximately 4 m in this experiment), beyond which the vehicle may deviate into obstacle regions.
As shown in Figure 7, within each speed stratum, data are divided into quartiles by centripetal acceleration (Q1 lowest, Q4 highest). Results demonstrate that AEKF large error occurrence rates increase significantly with centripetal acceleration across all speed strata: from 0% (Q1) to 40% (Q4) in the low-speed stratum (, ), from 25% to 53% in the medium-speed stratum (, ), and from 32% to 47% in the high-speed stratum (, ). This confirms that the probability of large errors correlates significantly with centripetal acceleration, providing statistical support for the theoretical prediction that amplifies the coupling term .
Figure 7.
Effect of centripetal acceleration on large error occurrence rate (error m), stratified by velocity. Analysis restricted to maneuvering segments ( ). Higher centripetal acceleration consistently increases AEKF large error probability across all speed strata ( tests, all ), while VQF-EKF maintains lower rates and greater robustness.
VQF-EKF demonstrates greater robustness against centripetal acceleration, maintaining substantially lower large error occurrence rates across all conditions. In the low-speed stratum, the performance gap widens from 0% at Q1 to 32% at Q4 (AEKF 40% vs. VQF 7%), indicating that VQF’s advantage becomes more pronounced under high- conditions where AEKF suffers severe performance degradation.
It is noted that in the medium-speed stratum at Q4, both methods exhibit similarly high large error rates (approximately 53%). In single-trajectory validation, this velocity-acceleration combination corresponds to a specific sharp turn segment where both methods experience degraded performance due to compound sensor-level factors (e.g., DVL beam geometry variations, transient magnetic disturbances). Since both methods are affected similarly, this does not contradict the main conclusion: VQF’s advantage lies in suppressing coupling-induced error amplification, not in eliminating sensor-level disturbances that affect both architectures. The overall statistical conclusion remains valid ( tests, all ).
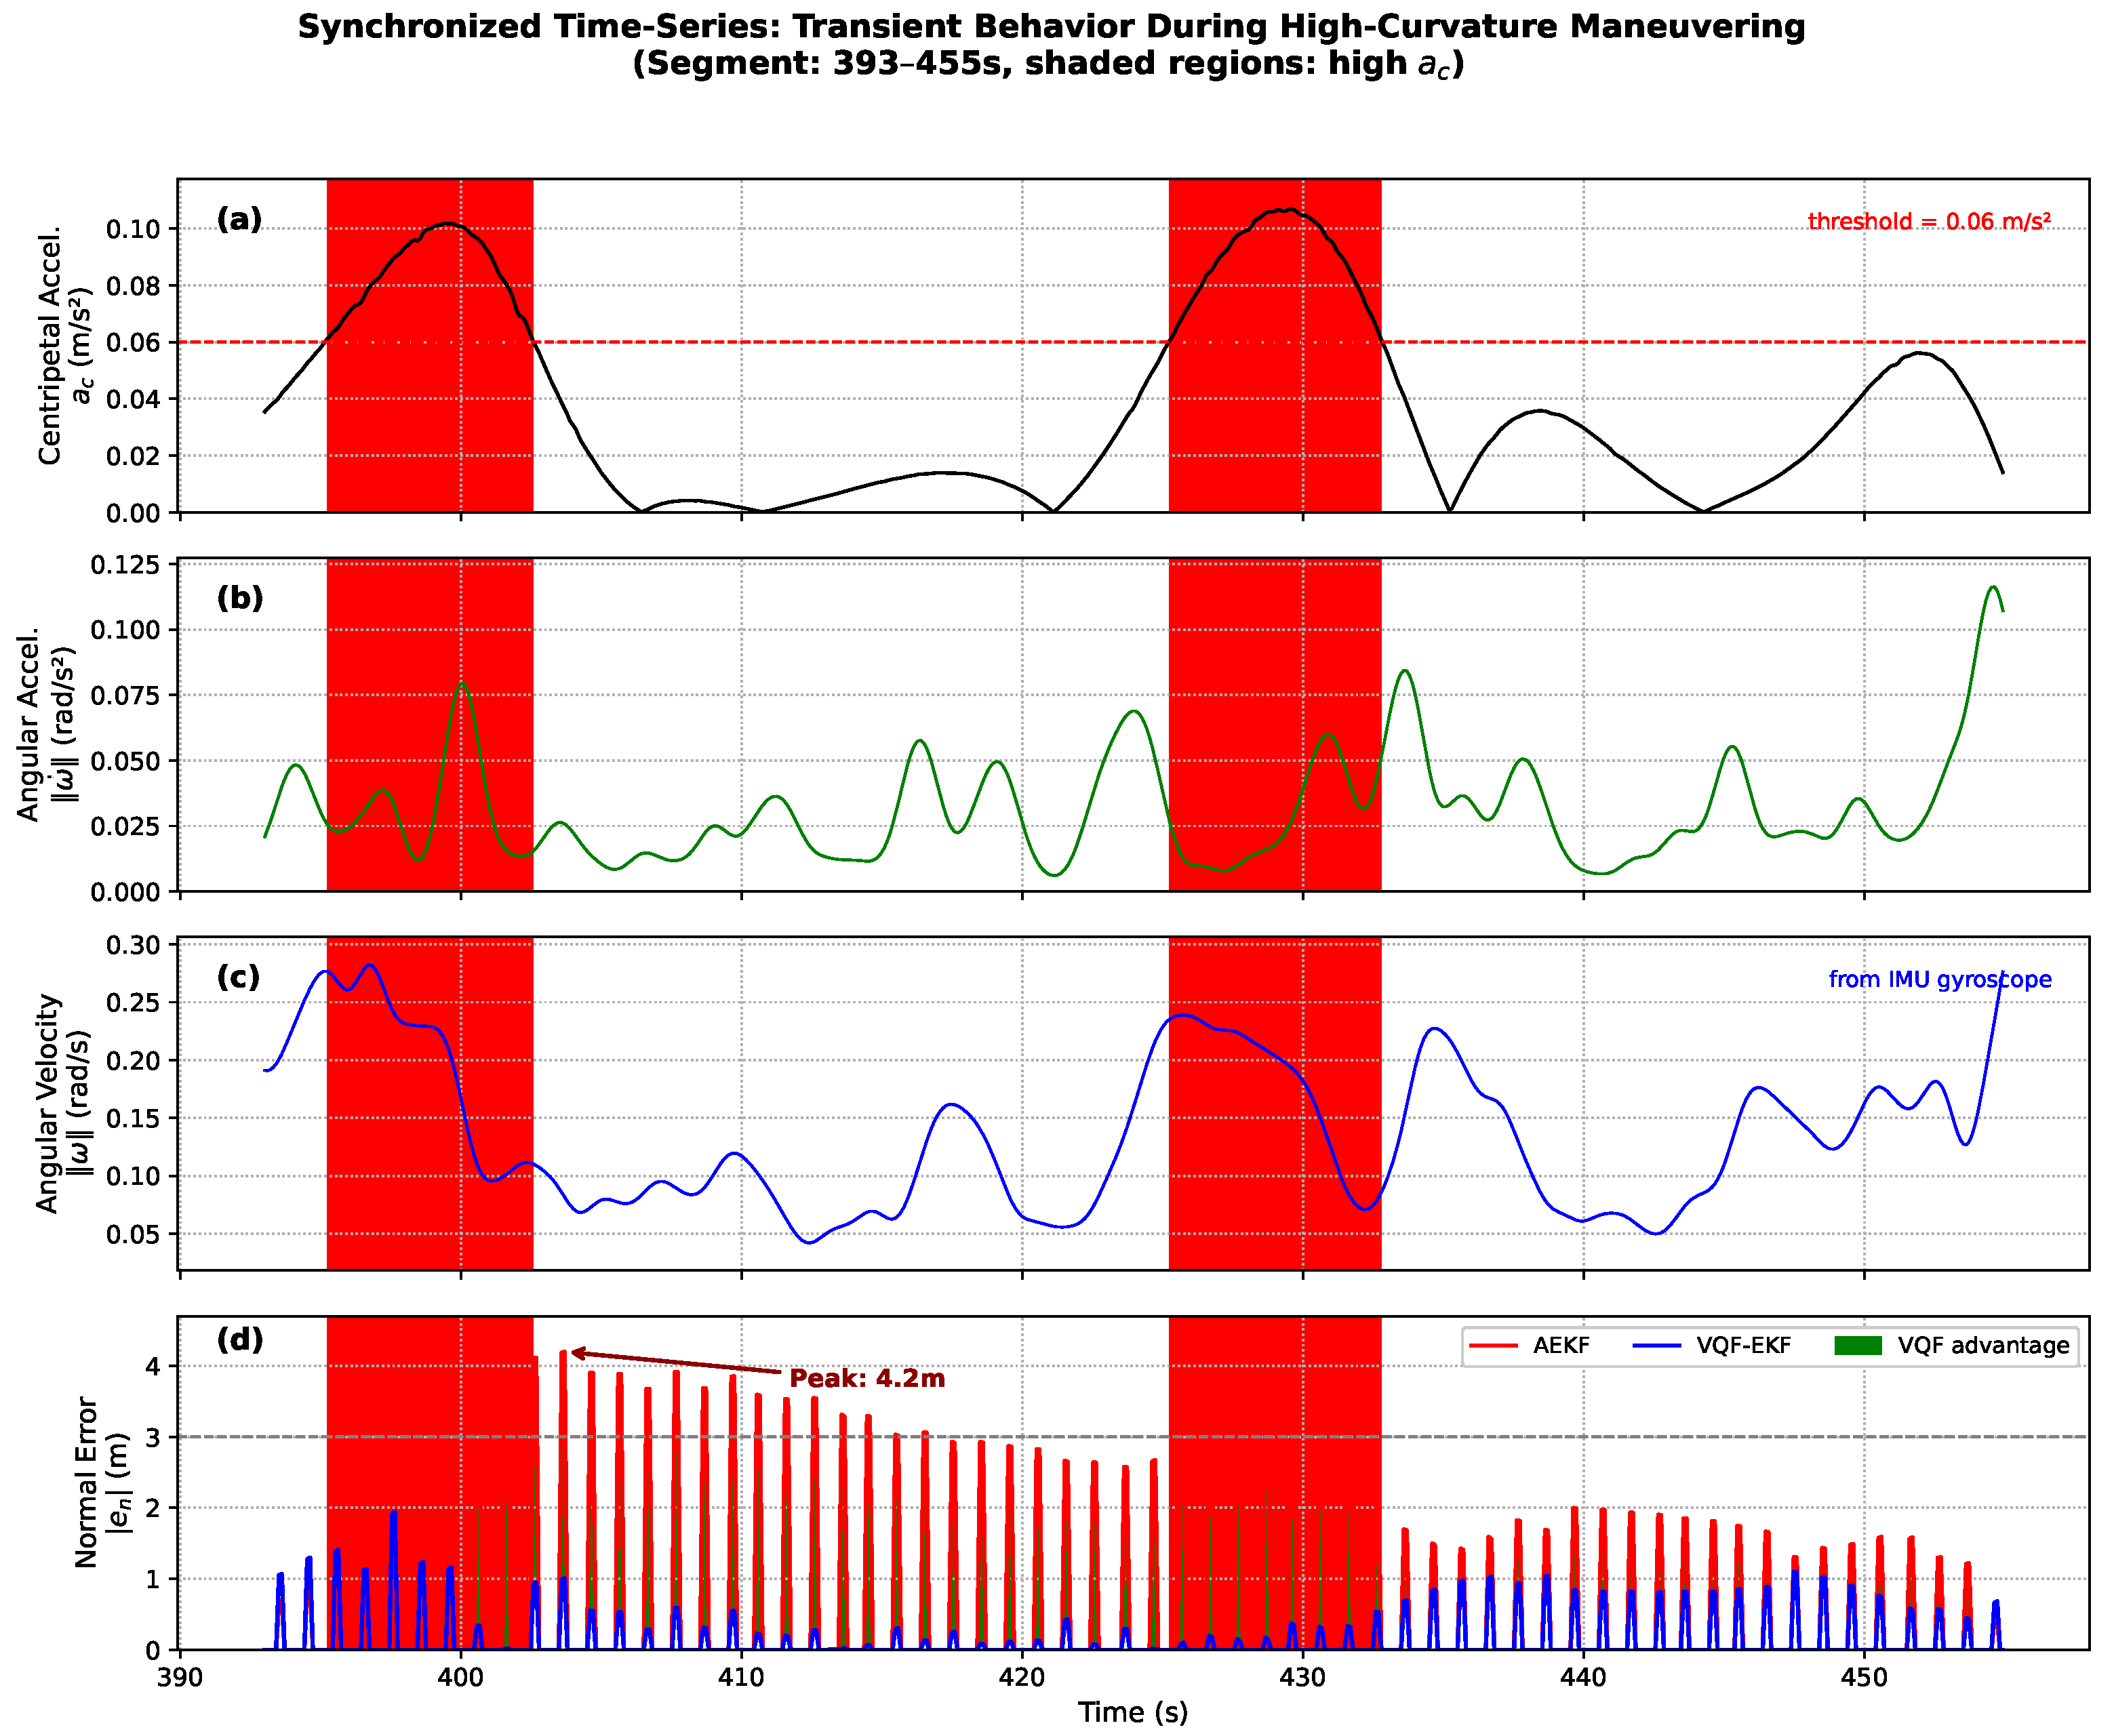
Beyond the statistical evidence, temporal examination provides direct visualization of the relationship between centripetal acceleration and navigation error. Figure 8 presents synchronized time-series for a representative high-curvature segment (393–455 s). The shaded regions indicate periods where m/. AEKF error peaks (reaching 4.2 m) occur during or immediately following these high- intervals, whereas VQF-EKF maintains consistently lower errors throughout.
Figure 8.
Synchronized time-series during high-curvature maneuvering (393–455 s). (a) Centripetal acceleration; (b) angular acceleration; (c) angular velocity; (d) normal error. Shaded regions indicate high- periods.
5.5. Experimental Conclusions
This chapter validates the effectiveness of the VQF-EKF hybrid architecture through measured trajectory experiments. Experimental results confirm the theoretical predictions from Section 2 regarding the decoupled architecture’s elimination of coupling errors:
- 1.
- For scenarios represented by the experimental data featuring multiple high-curvature maneuvers, global performance improvement is significant, achieving positioning accuracy enhancement compared to the AEKF baseline, validating the decoupled architecture’s effectiveness.
- 2.
- Segmentation analysis demonstrates maximum RMSE improvement in high-curvature segments (48% vs. 14–19% in other segments). Stratified centripetal acceleration analysis further reveals that the probability of large errors ( m) increases significantly with for AEKF ( tests, all ), while VQF-EKF exhibits greater robustness. These two complementary analyses—one based on average error, the other on tail-risk probability—consistently support the theoretical prediction in Section 2.1 that centripetal acceleration amplifies the coupling term .
- 3.
- Spatial heterogeneity characteristics indicate that VQF attitude decoupling effectively suppresses coupling errors in high-curvature scenarios, with the adaptive strategy accurately tracking noise variations in dynamic environments; however, the decoupled architecture exhibits adaptability issues in low-curvature scenarios.
Experimental findings provide empirical evidence for in-depth discussion in Section 6 and future research directions.
6. Discussion and Conclusions
This research designs a VQF-EKF decoupled architecture that suppresses attitude error propagation to velocity/position through independent attitude estimation. Experimental studies preliminarily demonstrate this strategy’s significant advantages in high-curvature scenarios, validating functional decoupling’s effectiveness in high-dynamic navigation. This result expands the architectural design space for underwater navigation filters, providing diversified architectural options for different scenario requirements.
The spatial heterogeneity characteristics revealed by experiments reflect the complexity and variability of underwater AUV mission scenarios. During high-risk maneuvers such as turning and obstacle avoidance, improvements in navigation accuracy exert the greatest impact on mission success rates, while minor performance differences in straight segments exert limited influence on overall missions. This makes VQF-EKF particularly suitable for high-maneuverability applications such as pipeline inspection, platform circumnavigation, and curved-path manipulation tasks. Simultaneously, segmentation analysis results provide clear directions for subsequent research: adaptive architecture switching based on motion states (decoupled for high curvature, fully coupled for low curvature) may prove more effective than parameter tuning within a single architecture.
This work positions itself as concept validation and characteristic analysis of the VQF-EKF architecture, with the experimental design’s core objective being verification of the theoretical derivation’s prediction that “centripetal acceleration amplifies coupling strength.” To this end, measured trajectories encompassing low, medium, and high curvature modes are selected for segmented verification, with experimental results highly consistent with theory. As the first measured validation of the decoupled architecture, the current work establishes performance baselines and reveals architectural characteristics, laying the foundations for subsequent expansion studies under different sensor configurations, environmental conditions, and voyage lengths. The experimental trajectory provides sufficient diversity for validating the theoretical predictions: velocity ranges from 0.3 to 0.9 m/s and centripetal acceleration spans 0.01 to 0.22 m/, enabling stratified analysis across different operating conditions. As shown in Figure 7, consistent performance advantages are observed across three velocity strata. The sensor configuration (tactical-grade FOG-IMU with DVL accuracy of ) represents typical AUV operational setups. Since the theoretical mechanism that centripetal acceleration amplifies the coupling term is independent of specific sensor grades, the findings are expected to generalize, though validation across different IMU grades (MEMS to navigation-grade) and DVL noise levels remains as future work.
The proposed architecture operates at a different level from algorithmic enhancements such as adaptive IMM or learning-aided methods. These approaches address model uncertainty and residual error compensation on top of a given filter structure, without altering the underlying coupling mechanism. The error amplification pathway analyzed in Section 2 persists regardless of such enhancements. The decoupled architecture addresses this structural issue and can serve as a foundational framework for integrating advanced algorithmic modules. Similarly, loosely coupled variants reduce but do not eliminate cross-covariance propagation, differing fundamentally from complete decoupling with explicit uncertainty compensation.
Future work primarily encompasses two directions:
- 1.
- Hybrid adaptive architecture strategy, intelligently switching between decoupled and fully coupled architectures through real-time motion state perception.
- 2.
- Improved parameter adaptive mechanisms, exploring intelligent parameter prediction based on deep learning or multi-model switching through motion pattern recognition. Additionally, efforts should advance multi-sensor fusion, long-endurance evaluation, and embedded platform engineering deployment.
Author Contributions
Conceptualization, L.Z. and B.C.; methodology, B.C.; software, B.C.; validation, B.C., Y.L. and F.C.; formal analysis, B.C.; investigation, B.C.; resources, L.Z., X.M., P.Y. and B.L.; data curation, B.C. and F.C.; writing—original draft preparation, B.C.; writing—review and editing, B.C., B.L., P.Y., Y.L., F.C. and X.M.; visualization, B.C. and P.Y.; supervision, L.Z., B.L. and S.Y.; project administration, L.Z. and B.L.; funding acquisition, L.Z. All authors have read and agreed to the published version of the manuscript.
Funding
This research was funded by the Key R& D Program of Shandong Province, China, undergrant number 2023ZLGX04.
Institutional Review Board Statement
Not applicable.
Informed Consent Statement
Not applicable.
Data Availability Statement
The data presented in this study are available on request from the corresponding author.
Acknowledgments
The authors gratefully acknowledge technical support from the Collaborative Innovation Research Institute of Ocean Engineering and the experimental data provided by Harbin Engineering University during the research phase of this work. All individuals and institutions acknowledged here have provided their consent for this acknowledgment.
Conflicts of Interest
Authors Yu Lu and Fengluo Chen were employed by the company China Merchants Marine and Offshore Research Institute Co., Ltd. The remaining authors declare that the research was conducted in the absence of any commercial or financial relationships that could be construed as a potential conflict of interest.
Nomenclature
| Category | Symbol | Description |
| State Variables | State vector | |
| , | Position and position error [m] | |
| , | Velocity and velocity error [m/s] | |
| Attitude error vector [rad] | ||
| Gyroscope bias [rad/s] | ||
| Accelerometer bias [m/] | ||
| Quaternions | Attitude quaternion | |
| Gyroscope-integrated quaternion | ||
| Tilt-corrected quaternion | ||
| Final attitude quaternion | ||
| Incremental rotation quaternion | ||
| Matrices | State transition matrix | |
| Velocity-attitude coupling submatrix | ||
| , | Covariance and cross-covariance matrix | |
| , | Attitude uncertainty covariance | |
| , | Process noise covariance and increment | |
| , | Measurement noise covariance and increment | |
| Kalman gain matrix | ||
| Observation matrix | ||
| Innovation covariance matrix | ||
| , | Body-to-navigation rotation matrix | |
| Measurements | , | Angular velocity (raw/bias-corrected) [rad/s] |
| Accelerometer measurement [m/] | ||
| DVL velocity in body frame [m/s] | ||
| Specific force in navigation frame [m/] | ||
| Innovation vector | ||
| Parameters | , | Sampling period/time step [s] |
| , | Noise scaling coefficients | |
| Innovation-based scaling factor | ||
| M, N | Window lengths (innovation/correction) | |
| Curvature [] or filter gain | ||
| Magnetometer time constant [s] | ||
| State history buffer | ||
| Uncertainty | , , | Attitude standard deviations [rad] |
| , , | Correction magnitudes [rad] | |
| , , | Sliding window buffers | |
| Skew-symmetric matrix operator | ||
| Physical | g | Gravitational acceleration [m/] |
| Centripetal acceleration [m/] | ||
| R | Turning radius [m] | |
| , , | Roll, pitch, yaw angles [rad] | |
| Abbreviations | AUV | Autonomous Underwater Vehicle |
| DVL | Doppler Velocity Log | |
| ESKF | Error-State Extended Kalman Filter | |
| IMU | Inertial Measurement Unit | |
| VQF | Versatile Quaternion-based Filter | |
| NED | North-East-Down coordinate frame |
References
- Ioannou, G.; Forti, N.; Millefiori, L.M.; Carniel, S.; Renga, A.; Tomasicchio, G.; Binda, S.; Braca, P. Underwater Inspection and Monitoring: Technologies for Autonomous Operations. IEEE Aerosp. Electron. Syst. Mag. 2024, 39, 4–16. [Google Scholar] [CrossRef] [Scilit]
- Xiang, X.; Yu, C.; Niu, Z.; Zhang, Q. Subsea Cable Tracking by Autonomous Underwater Vehicle with Magnetic Sensing Guidance. Sensors 2016, 16, 1335. [Google Scholar] [CrossRef] [Scilit]
- Fun Sang Cepeda, M.; Freitas Machado, M.d.S.; Sousa Barbosa, F.H.; Santana Souza Moreira, D.; Legaz Almansa, M.J.; Lourenço de Souza, M.I.; Caprace, J.D. Exploring Autonomous and Remotely Operated Vehicles in Offshore Structure Inspections. J. Mar. Sci. Eng. 2023, 11, 2172. [Google Scholar] [CrossRef] [Scilit]
- Simetti, E.; Casalino, G. Manipulation and Transportation with Cooperative Underwater Vehicle Manipulator Systems. IEEE J. Ocean. Eng. 2017, 42, 782–799. [Google Scholar] [CrossRef] [Scilit]
- Littlefield, R.H.; Jaffre, F.; Kaeli, J.W. AUV Propulsion and Maneuvering by Means of Asymmetric Thrust. In 2018 IEEE/OES Autonomous Underwater Vehicle Workshop (AUV); IEEE: Piscataway, NJ, USA, 2018; pp. 1–6. [Google Scholar] [CrossRef] [Scilit]
- Zhou, J.; Si, Y.; Chen, Y. A Review of Subsea AUV Technology. J. Mar. Sci. Eng. 2023, 11, 1119. [Google Scholar] [CrossRef] [Scilit]
- Mei, X.; Han, D.; Saeed, N.; Wu, H.; Miao, F.; Xian, J.; Chen, X.; Han, B. Navigating the depths: A stratification-aware coarse-to-fine received signal strength-based localization for internet of underwater things. Front. Mar. Sci. 2023, 10, 1210519. [Google Scholar] [CrossRef] [Scilit]
- Tan, H.P.; Diamant, R.; Seah, W.K.; Waldmeyer, M. A survey of techniques and challenges in underwater localization. Ocean Eng. 2011, 38, 1663–1676. [Google Scholar] [CrossRef] [Scilit]
- Fomekong, F.R.M.; Jia, B.; Xu, Z.; Fred, B. Advancements in Sensor Fusion for Underwater SLAM: A Review on Enhanced Navigation and Environmental Perception. Sensors 2024, 24, 7490. [Google Scholar] [CrossRef] [Scilit]
- Wei, X.; Fan, S.; Zhang, Y.; Gao, W.; Shen, F.; Ming, X.; Yang, J. A robust adaptive error state Kalman filter for MEMS IMU attitude estimation under dynamic acceleration. Measurement 2025, 242, 116097. [Google Scholar] [CrossRef] [Scilit]
- Liu, S.; Zhang, T.; Zhang, J.; Zhu, Y. A New Coupled Method of SINS/DVL Integrated Navigation Based on Improved Dual Adaptive Factors. IEEE Trans. Instrum. Meas. 2021, 70, 8504211. [Google Scholar] [CrossRef] [Scilit]
- Groves, P.D. Principles of GNSS, Inertial, and Multisensor Integrated Navigation Systems—Second EditionPaul D. Groves Artech House, 2013, 776 pp ISBN-13: 978-1-60807-005-3. J. Navig. 2014, 67, 191–192. [Google Scholar] [CrossRef] [Scilit]
- Borodacz, K.; Szczepański, C. Impact of Motion-Dependent Errors on the Accuracy of an Unaided Strapdown Inertial Navigation System. Sensors 2023, 23, 3528. [Google Scholar] [CrossRef] [Scilit]
- Qin, X.; Zhang, R.; Wang, G.; Long, C.; Hu, M. Robust Interactive Multimodel INS/DVL Intergrated Navigation System with Adaptive Model Set. IEEE Sens. J. 2023, 23, 8568–8580. [Google Scholar] [CrossRef] [Scilit]
- Wang, D.; Xu, X.; Hou, L. An improved adaptive Kalman filter for underwater SINS/DVL system. Math. Probl. Eng. 2020, 2020, 5456961. [Google Scholar] [CrossRef] [Scilit]
- Xu, B.; Guo, Y.; Hu, J. An Improved Robust Kalman Filter for SINS/DVL Tightly Integrated Navigation System. IEEE Trans. Instrum. Meas. 2021, 70, 8502915. [Google Scholar] [CrossRef] [Scilit]
- Atia, M.M.; Waslander, S.L. Map-aided adaptive GNSS/IMU sensor fusion scheme for robust urban navigation. Measurement 2019, 131, 615–627. [Google Scholar] [CrossRef] [Scilit]
- Salavasidis, G.; Munafo, A.; Harris, C.A.; Prampart, T.; Templeton, R.; Smart, M.; Roper, D.T.; Pebody, M.; McPhail, S.D.; Rogers, E.; et al. Terrain-aided navigation for long-endurance and deep-rated autonomous underwater vehicles. J. Field Robot. 2019, 36, 447–474. [Google Scholar]
- Paull, L.; Saeedi, S.; Seto, M.; Li, H. AUV Navigation and Localization: A Review. IEEE J. Ocean. Eng. 2014, 39, 131–149. [Google Scholar] [CrossRef] [Scilit]
- Lyu, W.; Cheng, X.; Wang, J. Adaptive Federated IMM Filter for AUV Integrated Navigation Systems. Sensors 2020, 20, 6806. [Google Scholar] [CrossRef] [Scilit]
- Huang, H.; Chen, X.; Zhou, Z.; Xu, Y.; Lv, C. Study of the Algorithm of Backtracking Decoupling and Adaptive Extended Kalman Filter Based on the Quaternion Expanded to the State Variable for Underwater Glider Navigation. Sensors 2014, 14, 23041–23066. [Google Scholar] [CrossRef] [Scilit]
- Shaukat, N.; Ali, A.; Javed Iqbal, M.; Moinuddin, M.; Otero, P. Multi-Sensor Fusion for Underwater Vehicle Localization by Augmentation of RBF Neural Network and Error-State Kalman Filter. Sensors 2021, 21, 1149. [Google Scholar] [CrossRef] [Scilit]
- Laidig, D.; Seel, T. VQF: Highly accurate IMU orientation estimation with bias estimation and magnetic disturbance rejection. Inf. Fusion 2023, 91, 187–204. [Google Scholar] [CrossRef] [Scilit]
- Sabatini, A.M. Estimating Three-Dimensional Orientation of Human Body Parts by Inertial/Magnetic Sensing. Sensors 2011, 11, 1489–1525. [Google Scholar] [CrossRef] [Scilit]
- Klein, I.; Diamant, R. Observability Analysis of DVL/PS Aided INS for a Maneuvering AUV. Sensors 2015, 15, 26818–26837. [Google Scholar] [CrossRef] [Scilit]
- Huang, G.P.; Mourikis, A.I.; Roumeliotis, S.I. Observability-based rules for designing consistent EKF SLAM estimators. Int. J. Robot. Res. 2010, 29, 502–528. [Google Scholar] [CrossRef] [Scilit]
- Mohamed, A.; Schwarz, K. Adaptive Kalman filtering for INS/GPS. J. Geod. 1999, 73, 193–203. [Google Scholar]
- Liu, P.; Wang, B.; Deng, Z.; Fu, M. INS/DVL/PS Tightly Coupled Underwater Navigation Method with Limited DVL Measurements. IEEE Sens. J. 2018, 18, 2994–3002. [Google Scholar] [CrossRef] [Scilit]

Disclaimer/Publisher’s Note: The statements, opinions and data contained in all publications are solely those of the individual author(s) and contributor(s) and not of MDPI and/or the editor(s). MDPI and/or the editor(s) disclaim responsibility for any injury to people or property resulting from any ideas, methods, instructions or products referred to in the content. |
© 2026 by the authors. Licensee MDPI, Basel, Switzerland. This article is an open access article distributed under the terms and conditions of the Creative Commons Attribution (CC BY) license.