


Abstract
In this paper, three iterative methods (Stokes, Newton and Oseen iterative methods) based on finite element discretization for the stationary micropolar fluid equations are proposed, analyzed and compared. The stability and error estimation for the Stokes and Newton iterative methods are obtained under the strong uniqueness conditions. In addition, the stability and error estimation for the Oseen iterative method are derived under the uniqueness condition of the weak solution. Finally, numerical examples test the applicability and the effectiveness of the three iterative methods.
1. Introduction
The micropolar fluid equations can be used to describe the flow behavior of polymeric fluids. Based on the classical Navier–Stokes equations, Eringen [1] first proposed the micropolar fluid equations in 1965. The micropolar fluid equations postulate that every particle not only has mass and velocity but also has microinertia and microrotation, and can support not only stress, but couple stress. Micropolar fluids have been widely used in modern industry, biology, engineering and other fields. The dynamic behavior of fluid flow, such as particle suspensions, liquid crystals, lubrication and animal blood can be described by micropolar fluid equations [2,3].
Many scholars are devoted to study the well-posedness of solutions for the micropolar fluid equations. Galdi and Rionero [4] discussed the existence and uniqueness of weak solutions for the initial boundary value problem of the micropolar fluid equations. Rojas-medar and Boldrini [5] proved the global existence of weak solutions by the Galerkin method. Łukaszewicz [6,7] proved the local existence of strong solutions and the global existence of weak solutions by using the linearization method and fixed point theorems. Dong and Chen [8] proposed the regularity criteria of weak solutions for the 3D micropolar fluid equations.
In the past decades, the finite element method (FEM) has been widely used to solve the fluid dynamics equations. He and Li [9] introduced the three iterative methods for Navier–Stokes equations, and derived stability conditions for different iterative algorithms. Dong et al. [10] discussed and analyzed the three classical iterative methods for MHD equations. Based on the asymptotic behavior of the perturbation solutions of the steady Navier–Stokes equations, He [11] proposed the Euler implicit/explicit iterative scheme and proved the corresponding stability condition. In order to improve the calculation efficiency of Navier–Stokes equations, Xu [12], Xu and He [13] considered the two-level methods based on the iterative solutions. Layton [14,15] proposed and analyzed the two-level method to solve the nonlinearity. Huang et al. [16] proposed the two-level stabilized finite element method based on local Gauss integration. Readers can refer to [17,18,19,20] and the references cited to further understand the finite element iterative methods.
Recently, the FEM has been applied to solve the micropolar fluid equations. Ortega–Torres and Rojas–Medar [21] employed the fully discrete penalty finite element method to solve micropolar fluid equations, and proved optimal error estimates of linear velocity, pressure, and angular velocity. Nochetto et al. [22] proposed the first-order semi-implicit fully discrete finite element method. Jiang and Yang [23] proposed some projection methods and analyzed the stability and error estimates for the classical first-order projection scheme. Maimaiti and Liu [24] proposed first-order and second-order pressure-modified projection methods, and analysed the stability of time semi-discrete and fully discrete schemes.
According to the above literature summarization, the finite element method and three iterative methods have been successfully adopted to simulate Navier–Stokes equations, and some numerical achievements about the unsteady micropolar fluid equations are obtained. Numerical analysis and comparison of finite element iterative methods for the stationary micropolar fluid equation have not been reported in the open literature. It is well known that the stationary micropolar fluid equations are a strong coupled nonlinear system. This system contains two nonlinear terms, and velocity u, pressure p and angular velocity are coupled together. When the viscous effect in the micropolar fluid equations is weak, which means the nonlinear effect is strong, the main challenges of numerically solving it are how to construct efficient and stable iterative algorithms, rigorous theoretical analysis and application in practical problems. Based on the above difficulties, the three iterative methods are considered.
In this paper, three iterative methods are presented to simulate the stationary micropolar fluid equations for the different viscosity effect. The uniform stability and convergence of the proposed methods are also analysed. The main conclusions are reported in Theorems 5–9. In the numerical example section, we compared the effectiveness of the three iterative methods. Meanwhile, the classical benchmark problems and the bearing lubrication problem with inhomogeneous boundary conditions are simulated.
The rest of this paper is organized as follows. In Section 2, some necessary theories of Sobolev spaces are introduced. In Section 3, the stability and error estimation of the finite element discrete problem is provided. In Section 4, the main part of this paper, the stability and error estimation of the three iterative methods under different uniqueness conditions are analyzed and compared. In Section 5, some numerical tests are provided to illustrate the correctness of the theoretic analysis and contrast the effectiveness of the proposed methods. In Section 6, the main conclusions of this paper are presented.
2. Preliminaries
In this paper, we assume that is a convex polygonal/polyhedral domain with Lipschitz continuous boundary in , or 3. We consider the stationary micropolar fluid equations as follows [1,6]:
where u is the velocity, p is the pressure, is the angular velocity, f and g are the external force terms, is the kinematic Newtonian viscosity, is the dynamic microrotation viscosity, and the positive constants are new viscosities connected with the asymmetry of the stress tensor, respectively. In order to simplify the calculation, we set , and introduce the general definition of the curl operator as
In particular, when , let
For simplicity, let consider the following homogeneous boundary conditions:
Let be the standard Sobolev spaces for all nonnegative integers k and r with norm . As usual, the Hilbert space are equipped with norm when . To obtain the weak formulation of (1)–(2), we introduce the following Sobolev spaces
For simplicity, we employ the product space with the usual graph norm for all . The space denotes the dual of with the norm:
where denotes duality product between the function spaces and its dual.
For the purpose of the subsequent analysis, the following bilinear and trilinear forms are introduced:
The following estimates about the trilinear form are classical [18,20,25].
where N is a constant, is a positive constant that may dependent on . The following Sobolve spaces inequalities are used frequently
According to the above estimates,  older inequality, Sobolev inequalities and the following inequalities
the following properties of and can be derived: , there holds
where and .
older inequality, Sobolev inequalities and the following inequalities
Note that the bilinear form is continuous on and satisfies the classical inf–sup condition [6,18]:
Next, let us define the following norms:
For the sake of convenience in writing, we set
Łukaszewicz in [6] proved the existence and uniqueness of the weak solution of (1) and (2) by considering the auxiliary elliptical linear problem and adopting the Leray–Schauder principle. Next, we give a new proof of well-posedness by using the Banach fixed point theorem.
Theorem 1.
Proof.
Let us define the function space
For given , we consider the following linear problem:
From the saddle-point theory [18], the problem (17) possesses a unique solution . Taking and , using (11) and (12) we can drive the (16).
Next, let us prove the uniqueness condition (15). From the problem (17), we can define the mapping
such that , and satisfy the following equation
Making a difference for and in (18) and taking yields
According to the Banach fixed point theorem, we know that has a fixed point in Z, which is the solution of problem (9). This completes the proof. □
Theorem 2.
Suppose and , then the solution of the problem (9) satisfies the following regularity
Proof.
The proof is put in “Appendix A”. □
3. Finite Element Approximation
In this section, let be a regular and quasi-uniform partition of into triangles for or tetrahedras for , and is a real positive parameter tending to 0. Next, we employ the following conforming finite element pairs to approximate the velocity, angular velocity and pressure.
where is the bubble function, and denotes the space of polynomials of a degree equal to 1 on K. For convenience, let . In this case, satisfies the following assumptions [6,17,18].
Assumption 1.
There exists a positive constantthat only depends on Ω such that
Assumption 2.
There exists a mapping satisfying
an -orthogonal projection operator satisfying
and a mapping satisfying
With the above discrete spaces, the finite element approximation of (9) reads: find such that
Similarly, let us define the discrete analogue of space V as
and introduce the discrete Laplace operator as
Furthermore, we have the following discrete estimates [9,17]:
Next, we prove the existence and uniqueness, stability and convergence of the discrete problem (26).
Lemma 1.
The trilinear term satisfies the following estimate
for all.
Theorem 3.
Proof.
The existence proof is obvious. Next, let us prove the stability and uniqueness.
For the second inequality, taking and in (26), we have
Using (28) and Young’s inequality yields
Theorem 4.
Suppose Assumptions 1 and 2 and the uniqueness condition (15) hold, we have the following error estimate
Proof.
The proof is put in “Appendix B”. □
4. Three Iterative Methods
Considering the effect of different viscosity coefficients, the three iterative methods for micropolar fluid equations are proposed.
Stokes iterative method:
find such that for all
Newton iterative method:
find such that for all
Oseen iterative method:
find such that for all
The initial value is defined by:
for all .
Next, we establish the stability and error estimates of the three iterative methods. For simplicity, let .
Lemma 2.
Under the conditions of Theorem 1, Assumptions 1 and 2, the initial value satisfies
the initial errors and satisfy the following bounds
Proof.
Let , in (36) and applying (11), the first term of (37) can be deduced. Similarly, choosing and , the second term of (37) can be derived.
Then, using the discrete inf-sup condition (22) gives that
The proof is completed. □
Theorem 5.
Under the conditions of Theorem 1, Assumptions 1 and 2, if
then defined by the Stokes iterative method satisfies
and satisfy the following bounds
for all.
Proof.
Firstly, we give the stability estimate. By Lemma 4.1, it can be checked that (43) is valid for . Let in (33) and subtract (36) from (33) with , we have
Then, let and taking in (33), we have
Suppose that (43) holds for . We now turn to prove that it is right for . Two adjacent iterative steps are subtracted, and taking in (33), we deduce that
In terms of (33), taking and leads to
Next, taking in (33) and using Lemma 4.1, we have
Furthermore, we assume , from (53) and Young’s inequality that
It is obvious that (44) holds for . Suppose that (44) holds for . Let us prove it valid for . Taking in (56) and using (11)–(13), (16), (42) and (52) lead to
The proof is finished. □
Theorem 6.
Under the conditions of Theorem 1, Assumptions 1 and 2, if
then defined by the Newton iterative method satisfies
and satisfy the following bounds
for all .
Proof.
By Lemma 4.1, we know that the (60) holds for . Setting in (34) and subtracting (36) from (34) with , we obtain
Taking and in (34), we have
Taking and in (34), we have
Now, we prove the second term of (60) holds for . Assuming it is correct for . Taking in (34) and combining Lemma 4.1 and Young’s inequality, we have
Applying the similar technique used in Theorem 5 and some simple calculations, we can obtain the second term of (60).
The Equation (38) shows the first term (61) holds for . Suppose that it holds for . Taking and in (72), using (11), (13), (16), (59) and (70), we conclude that
which yields that
The proof is finished. □
Theorem 7.
Under the conditions of Theorem 1, Assumptions 1 and 2, if
then defined by the Oseen iterative method satisfies
andsatisfy the following bounds
for all .
Proof.
We can easily deduce that (77) holds when . Taking in (35), and applying (11), (12) and (15), we obtain the first term of (77).
Then, setting and in (35), we obtain
By using the same technique of Theorem 5, we get the second term of (77).
Obviously, the Equation (78) holds for . Taking in (80) and applying (11), (13), (29) and (76), we obtain
From the discrete inf–sup condition (22), we have
The proof is finished. □
In the next theorem, another expression of the error estimates will be given, which can be controlled by .
Theorem 8.
Under the conditions of Theorems 5–7, there hold
and satisfy
for the Stokes and Oseen iterative methods, and
for the Newton iterative method.
Proof.
With the help of the triangle inequality, we obtain
From Theorems 5–7, the Equation (83) can be derived.
Setting and in (80) leads to
Using (11), (13), (29) and (59), we have
where for and for . Similarly, taking in (72) and using the discrete inf-sup condition (22), we have
Thus, the (85) holds for the Newton iterative method and the proof ends. □
Remark 1.
The error factor σ is not easy to compute during program implementation. Hence, we can adopt the error estimate from Theorem 8. In this case, the error can be controlled by the iterative error and the mesh size h.
Theorem 9.
Under the conditions of Theorems 3–7, the optimal error estimates of the three methods satisfy
for the Stokes iterative method with;
for the Newton iterative method with;
for the Oseen iterative method with .
5. Numerical Examples
In this section, four numerical examples are presented to test the correctness of the theoretical results and the validity of the proposed methods. In the first two examples, the three iterative methods are implemented for different viscosity coefficients. Meanwhile, the triangular cavity problem and bearing lubrication problem are also simulated in the last two examples. The finite element pair is used to approximate and . We choose the public domain finite element software FreeFem [26] to implement the algorithms. For numerical implementations, the iterative tolerance is set as .
5.1. 2D/3D Problems with Exact Solutions
In this example, the 2D/3D problems with exact solutions are used to verify the rates of convergence. Set the fluid domain and choose the right-hand side functions f and g such that the analytical solutions are
for and
for .
The CPU time and the convergence orders of the three iterative methods are displayed in Table 1, Table 2 and Table 3 for , and Table A1, Table A2 and Table A3 for . From these tables, we observe that the errors are almost the same with the three iterative methods. The corresponding errors are of the order of , which accord with our theoretical analysis completely. In addition, from the data of the CPU time, the Newton iterative method is the most efficient when the mesh size is fixed. This is due to the Newton iterative method being of the convergence rate of the second order with respect to the iterative step m.
Table 1.
Stokes iterative method for 2D stationary micropolar fluid equations.
Table 2.
Newton iterative method for 2D stationary micropolar fluid equations.
Table 3.
Oseen iterative method for 2D stationary micropolar fluid equations.
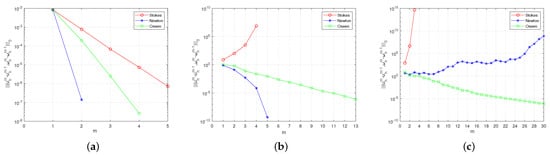
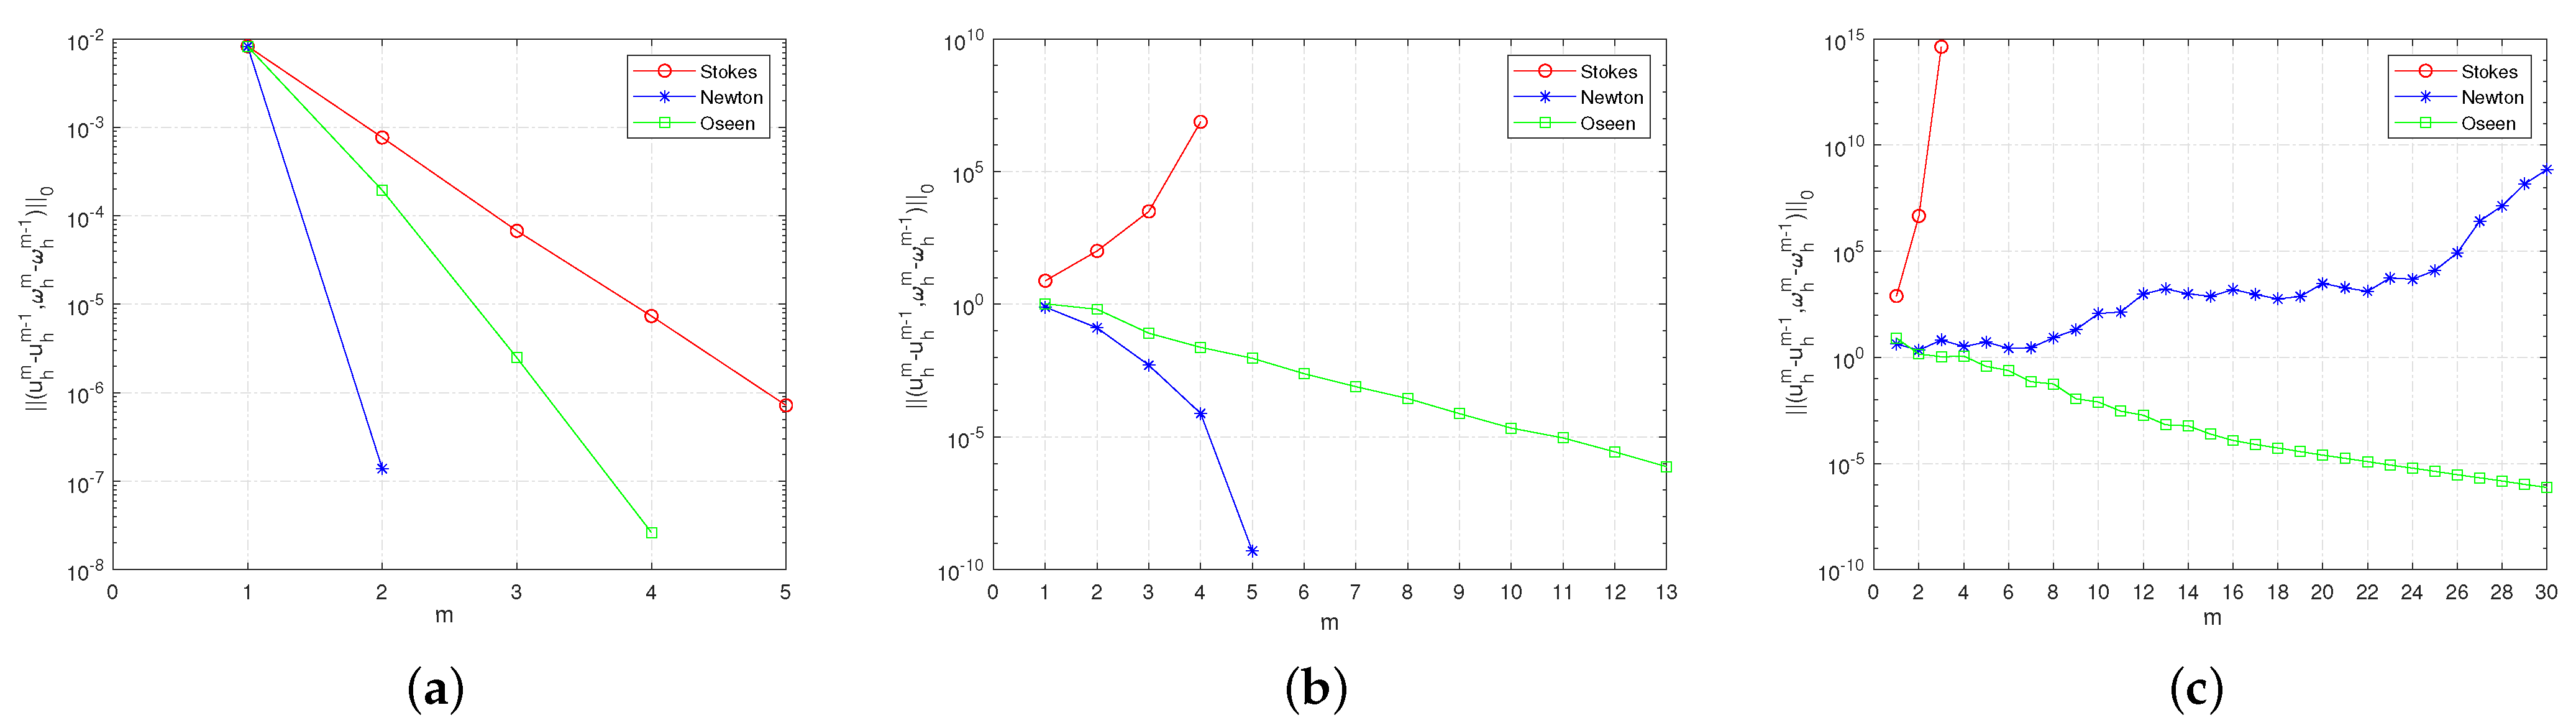
Figure 1 shows that in the 2D case, the convergence performance of the three iterative methods with different viscosity coefficients when the mesh size is fixed . We can find that when the viscosity coefficients are small, the three methods are effective. As the viscosity coefficients increases, the Stokes iterative method is no longer applicable. When the viscosity coefficients , only the Oseen iteration can maintain convergence. The results are agreed with the ones predicted by the theoretical analysis. Since the results of 2D and 3D are similar, we present only the 2D results here. Please refer to the Appendix C for 3D results.
Figure 1.
Comparison of iterative convergence errors with different viscosity coefficients. (a) . (b) . (c) .
5.2. Driven Cavity Flow
In this example, the classical benchmark problem, known as driven cavity flow is considered. Let the domain . The boundary condition for velocity reads on , and on the other three boundaries. Meanwhile, the angular velocity satisfies the homogeneous Dirichlet boundary condition.
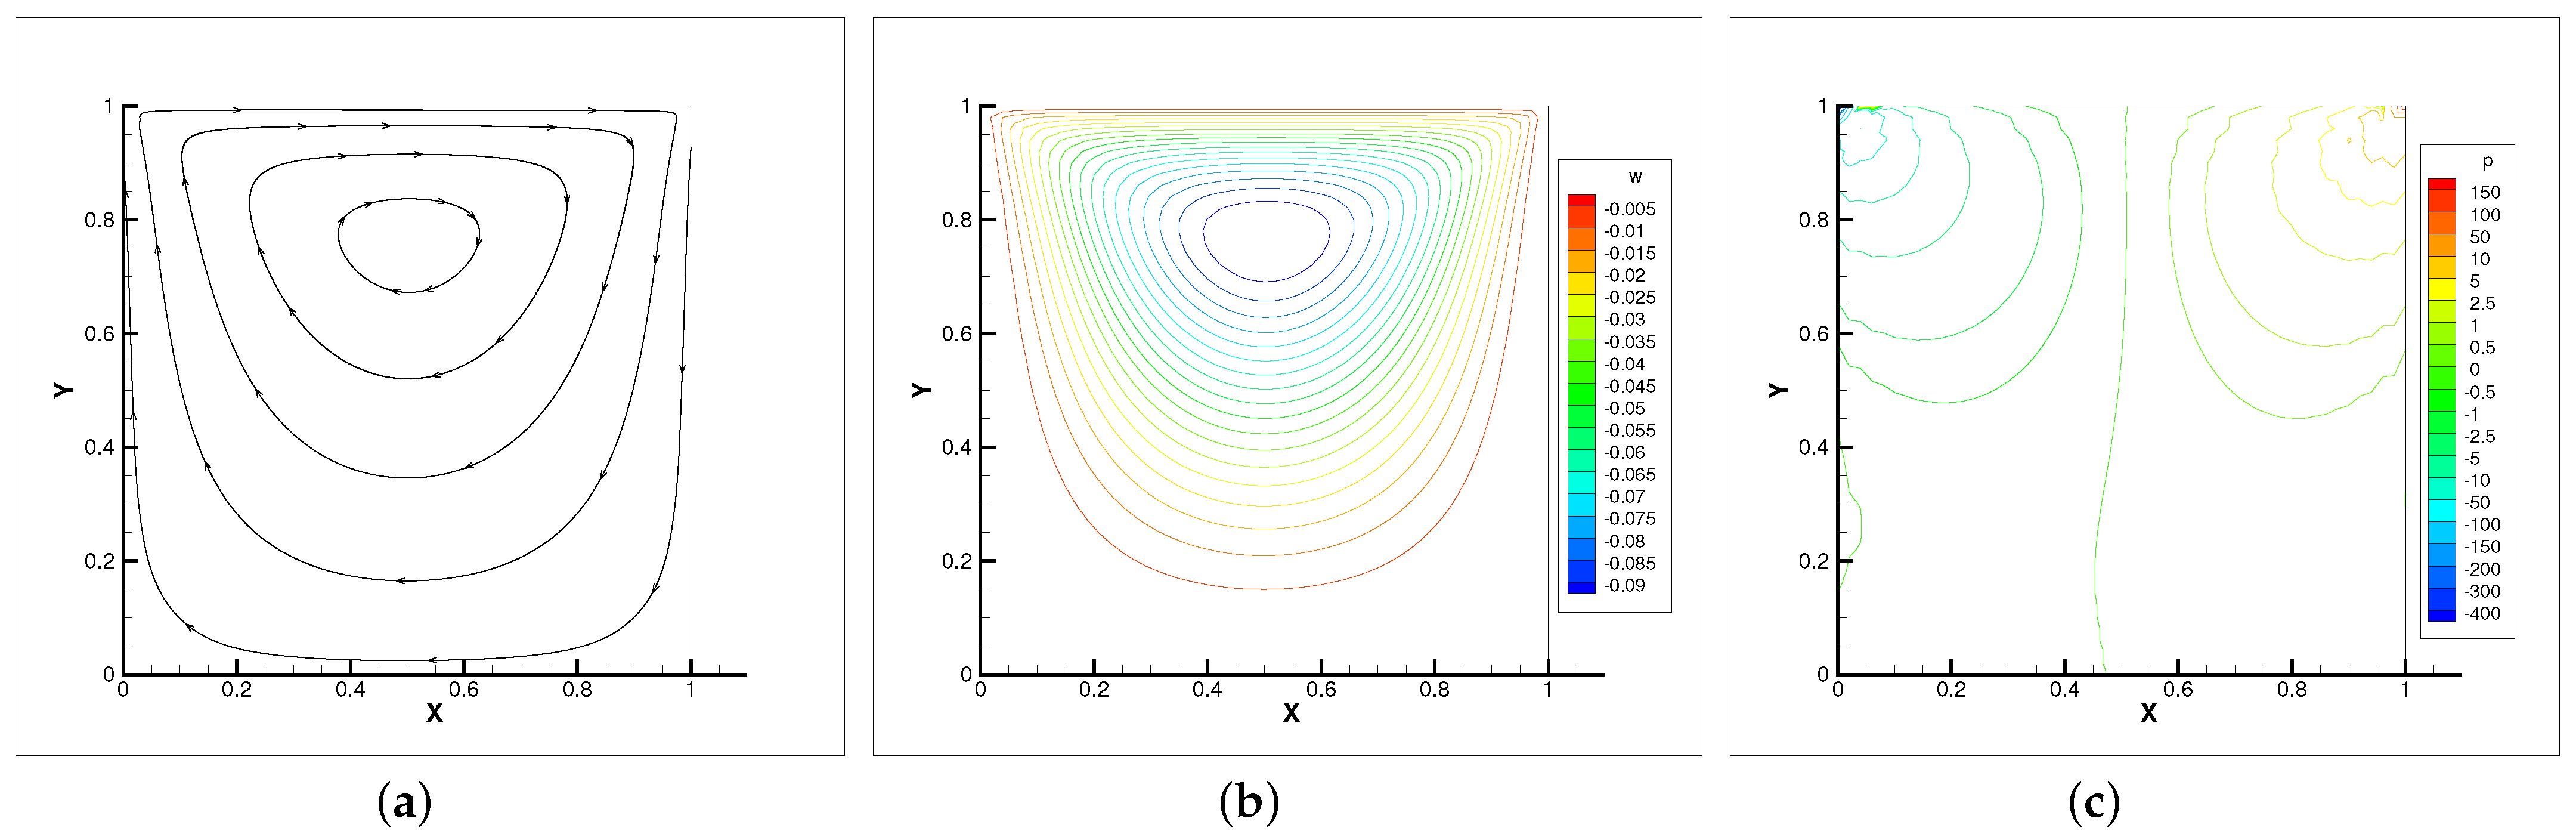
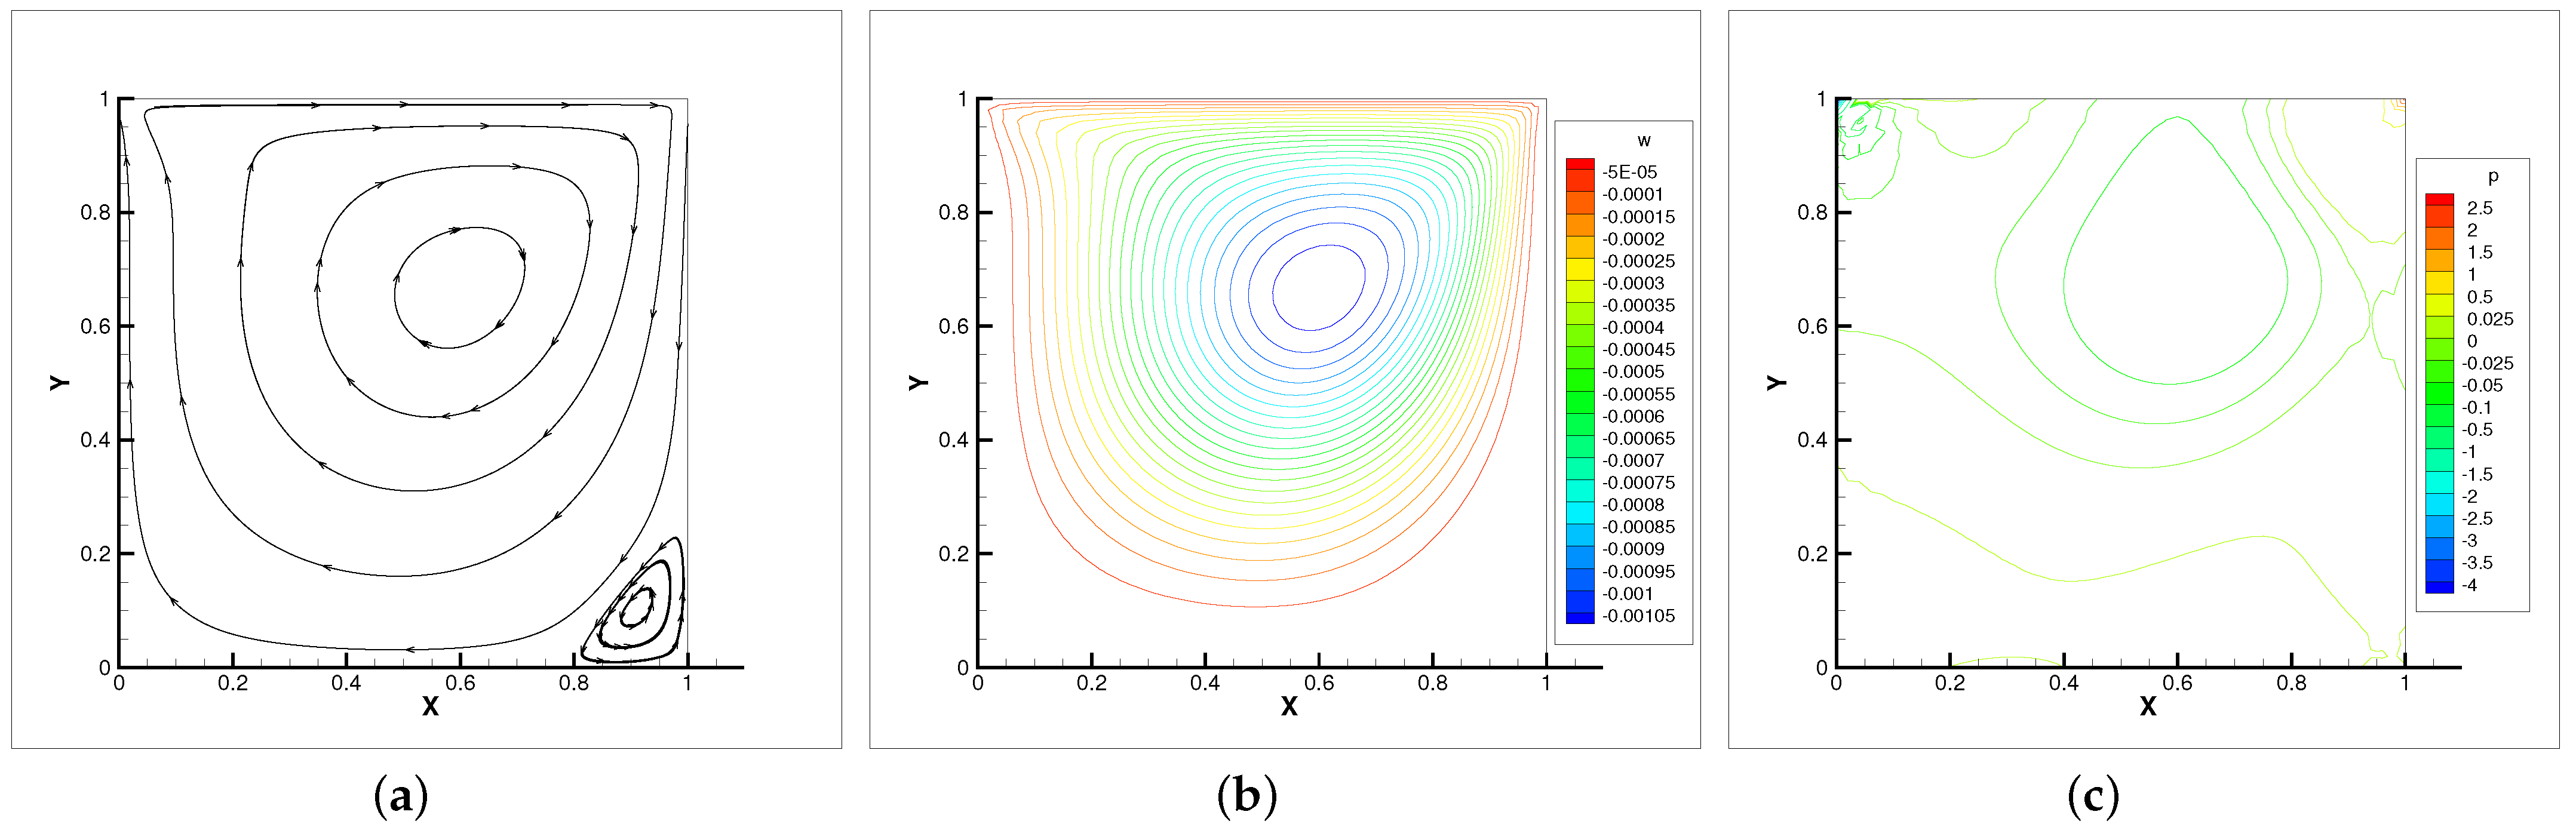
In Table 4, we compare the applicability of the three iterative methods under different viscosity coefficients. As the table shows, the Oseen iteration is the most flexible method. This is consistent with our theoretical analysis. Thus, the Oseen iterative method is adopted. In Figure 2, Figure 3 and Figure 4, the velocity streamlines, angular velocity contour lines of and pressure isobars for three different viscosity coefficients , , are displayed.
Table 4.
Comparison of the iterative numbers.
Figure 2.
Velocity streamlines (a), angular velocity contour lines (b) and pressure isobars (c) with .
Figure 3.
Velocity streamlines (a), angular velocity contour lines (b) and pressure isobars (c) with .
Figure 4.
Velocity streamlines (a), angular velocity contour lines (b) and pressure isobars (c) with .
It can be seen that when the viscosity is small, the velocity streamlines, angular contour lines and pressure isobars satisfy symmetry. With the viscosity decreases, the main vortex center moves towards the geometric center of the cavity. Meanwhile, the secondary vortices appear near the corner of the cavity. The flow property of micropolar fluids is almost identical with the Navier–Stokes equations in [27].
5.3. Triangular Cavity Flow
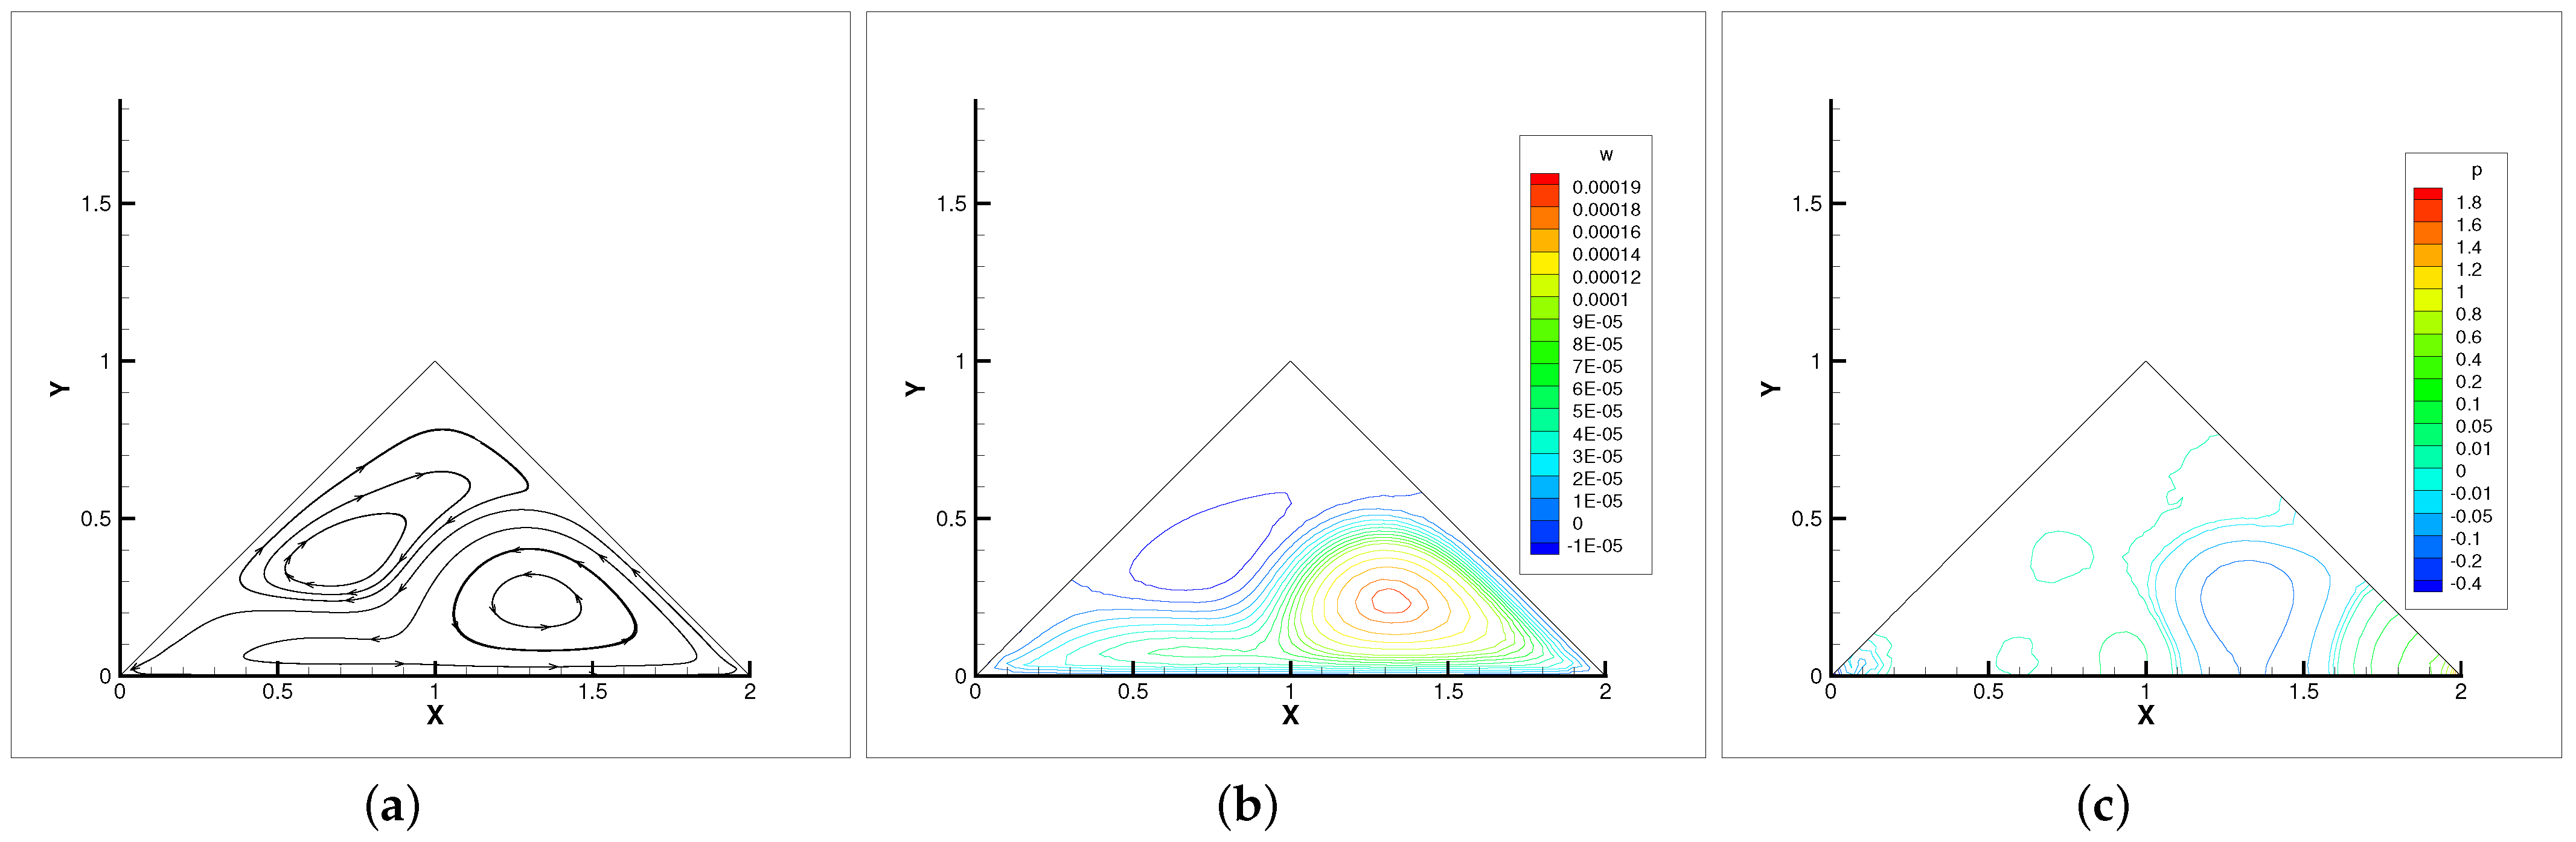
Motivated by [28], the flow of micropolar fluids inside an isosceles triangular cavity is considered. Figure A1 shows the schematic diagram of flow geometry and the computational mesh. Similarly, we only consider the Oseen iterative method in this example. Set , the boundary conditions are as follows:
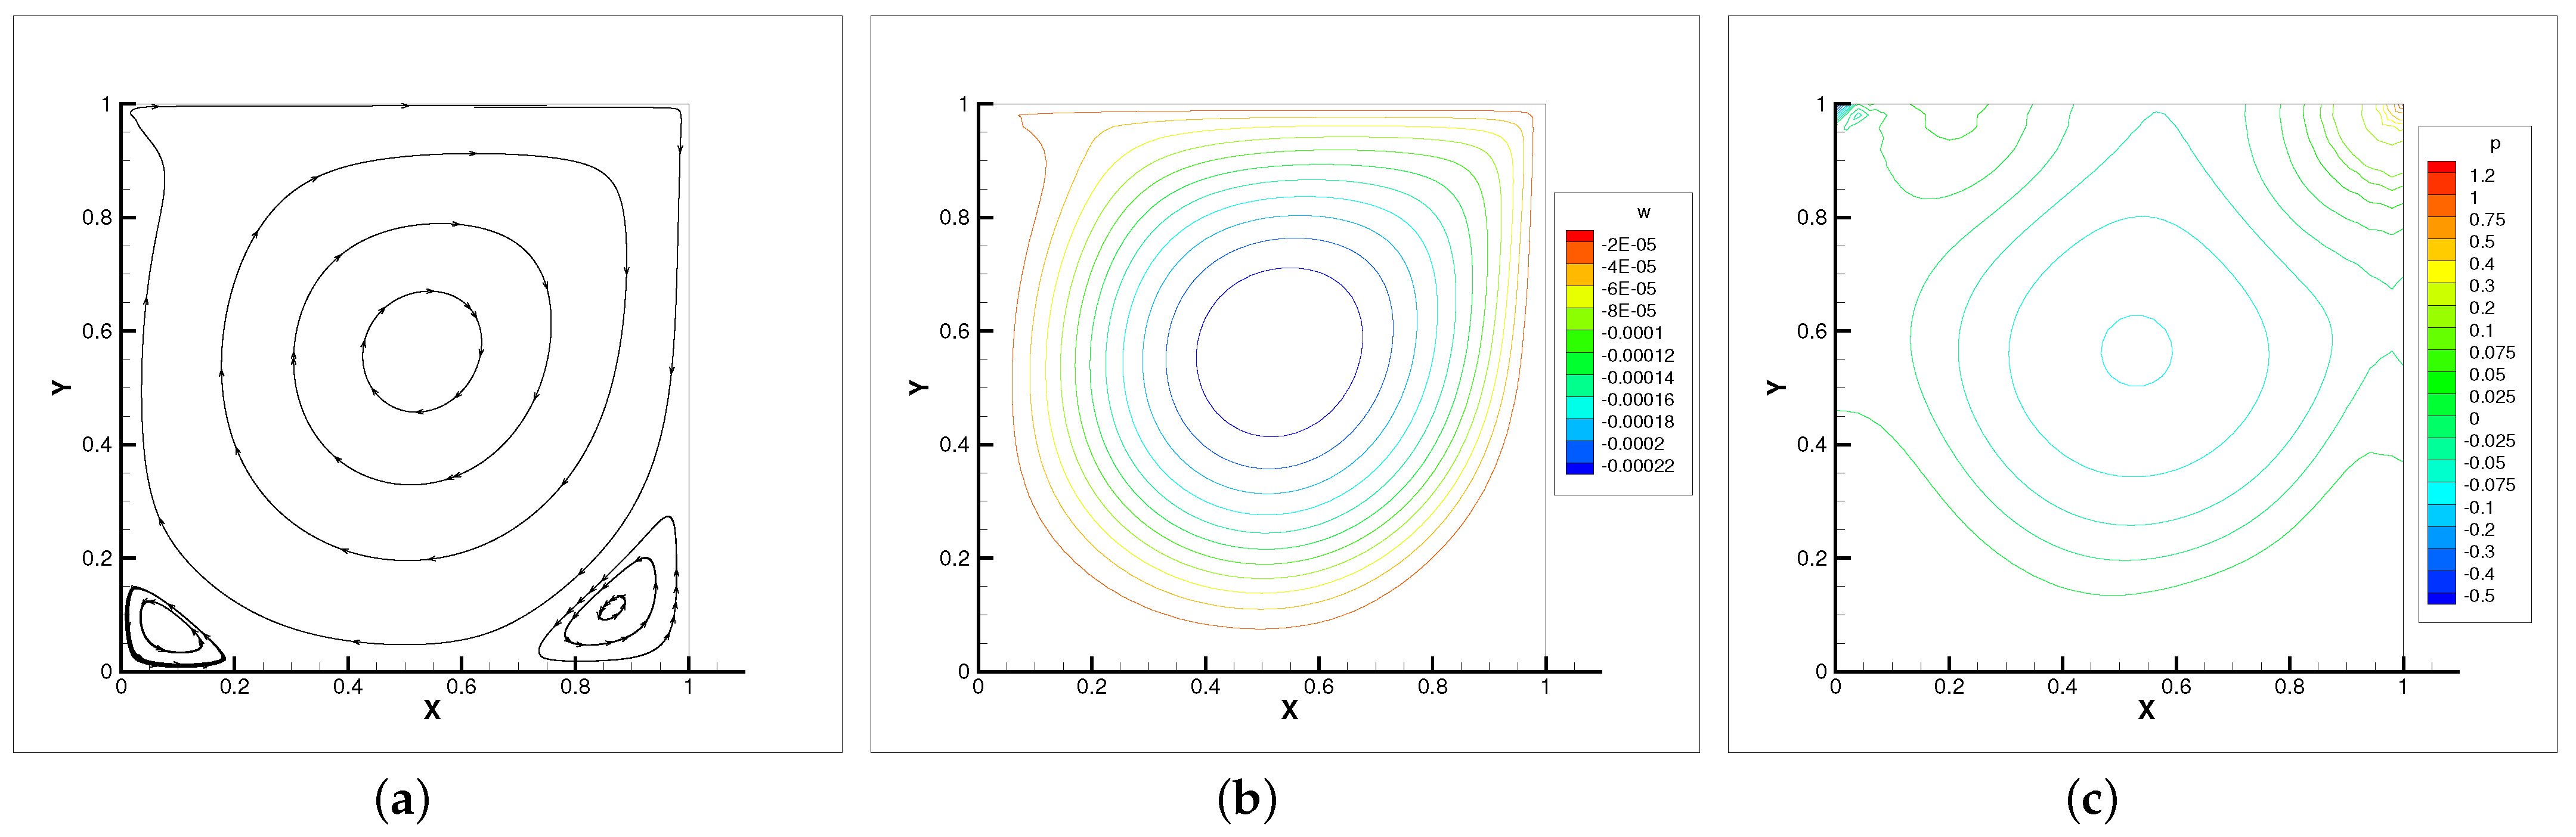
Similar to square cavity flow, when the hydrodynamic viscosity decreases, the velocity streamlines, angular velocity contour lines and pressure isobars no longer satisfy symmetry. In summary, the flow property is still exhibited as laminar flow. Please refer to the Appendix D for Figure A2, Figure A3 and Figure A4.
5.4. The Bearing Lubrication Problem
In ordinary operating conditions, the lubricant liquid can be considered as fluid suspension. Thus the micropolar fluid equations can be used to simulate the lubrication problem [29]. In this example, the application of micropolar fluids in a non-concentric bearing lubrication problem is considered. The fluid region is a ring domain between the outer boundary with radius and the inner boundary with radius .
We assume that velocity and angular velocity satisfy the homogeneous Dirichlet boundary condition at the boundary . On the boundary , the velocity and angular velocity satisfy , and . Here, represents the rotational angular velocity. Let and . We consider the three cases: = 200, 600, 1000.
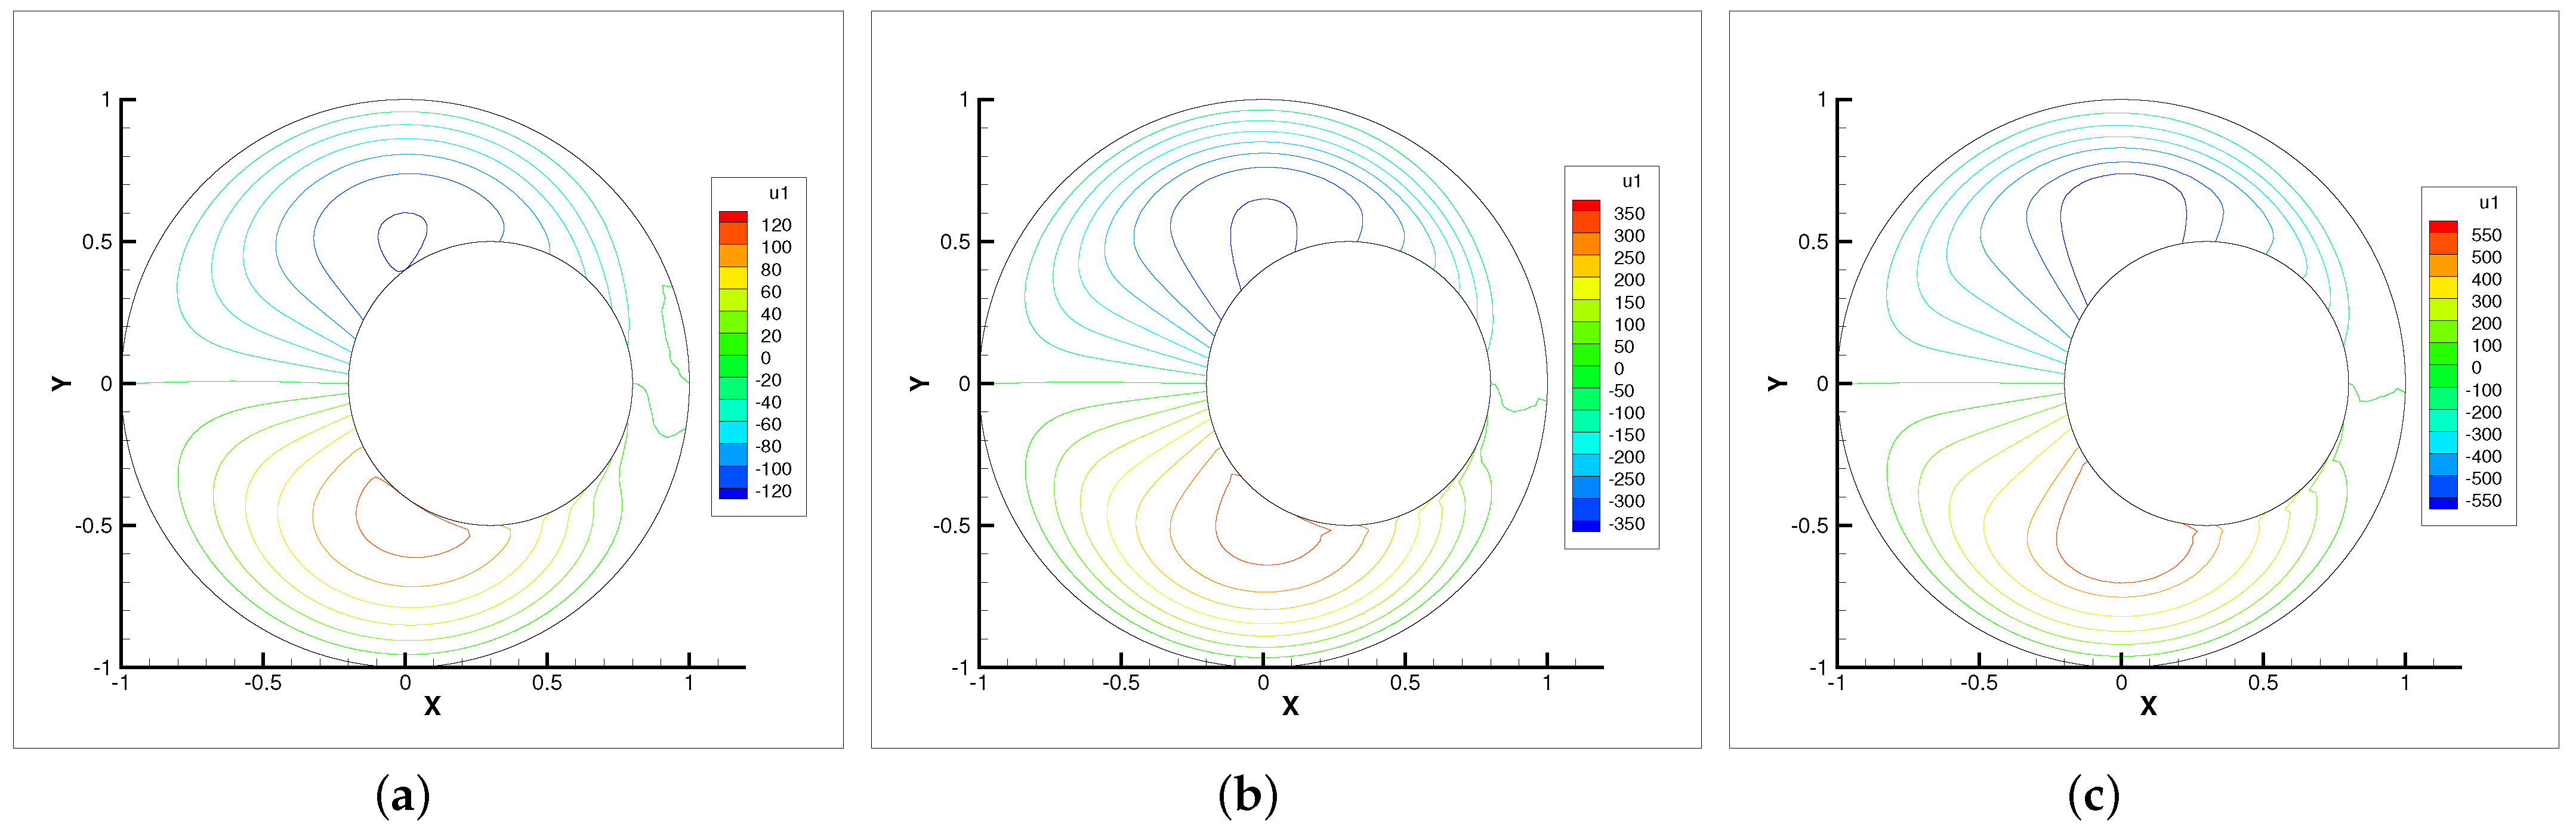
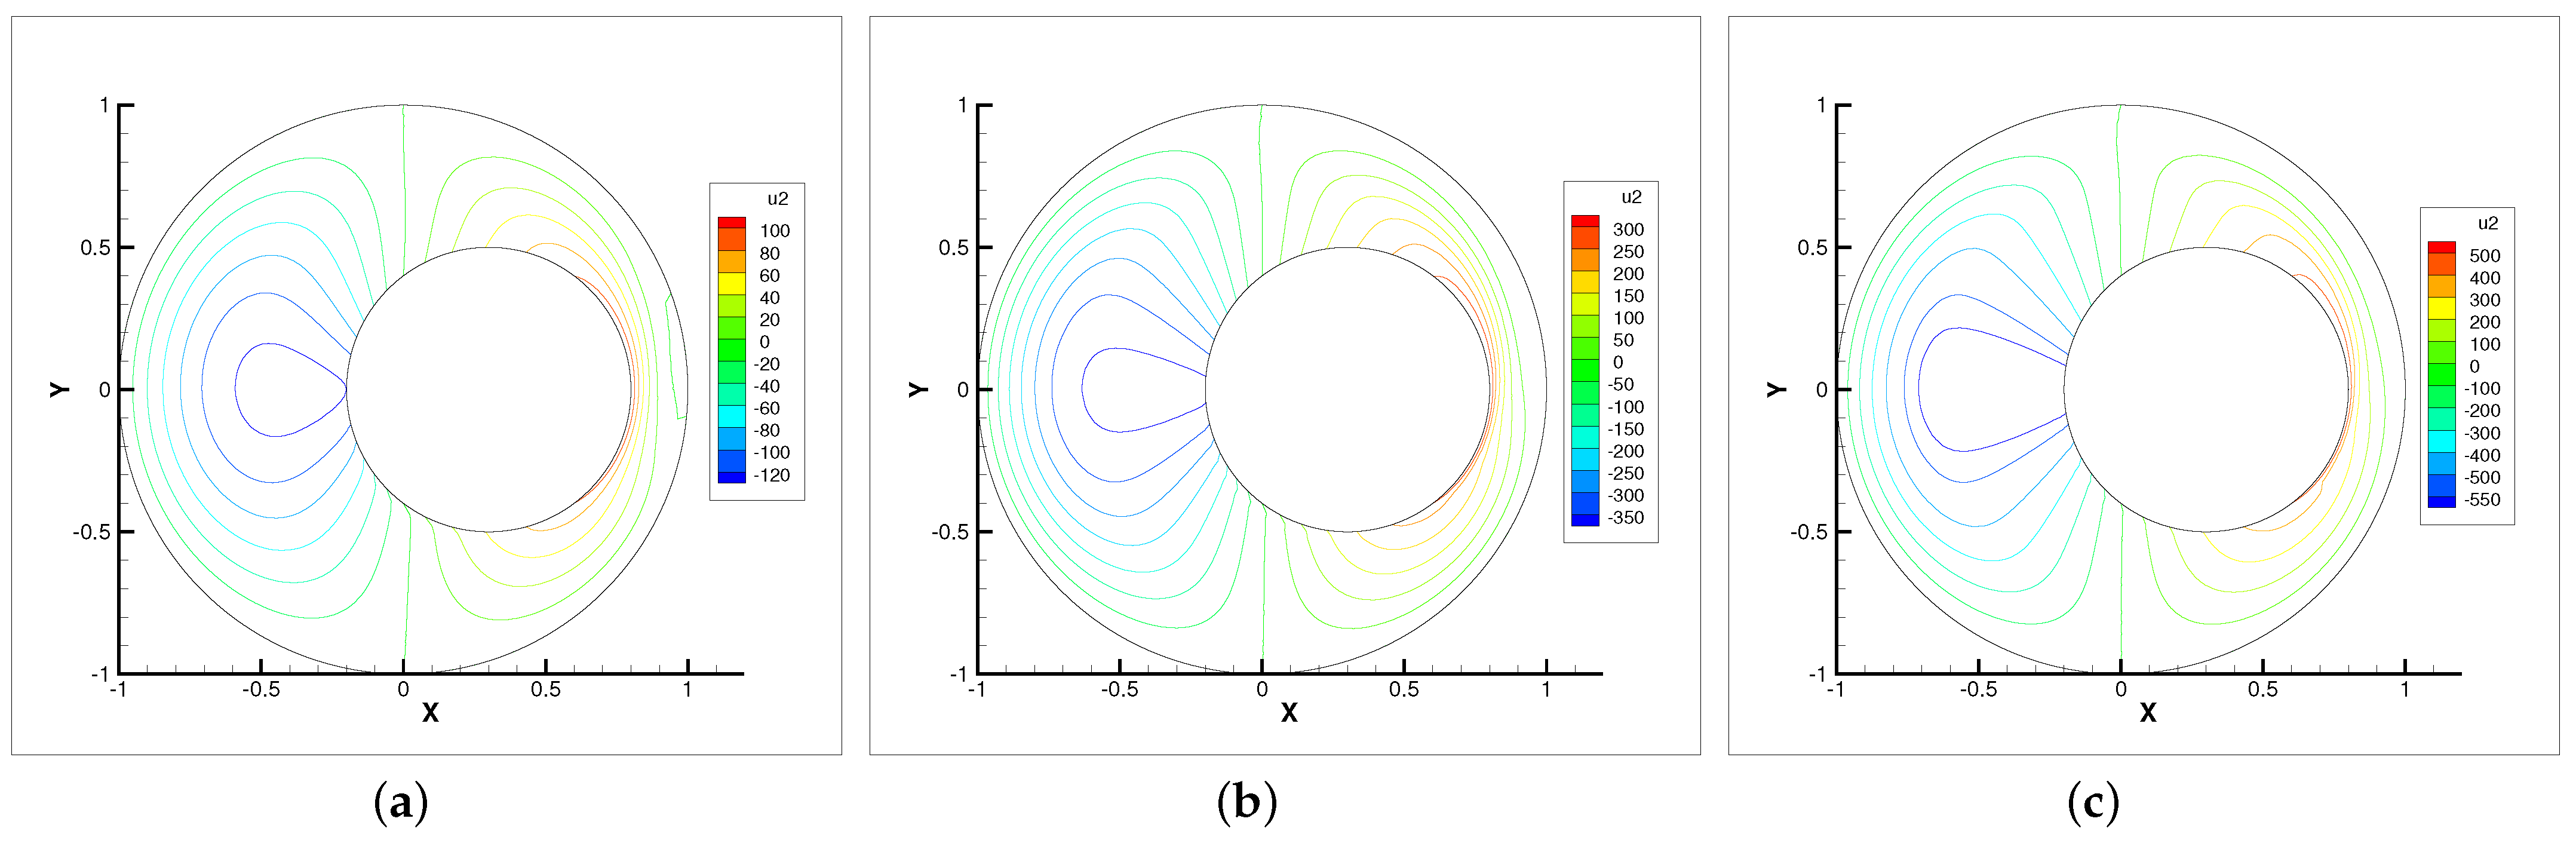
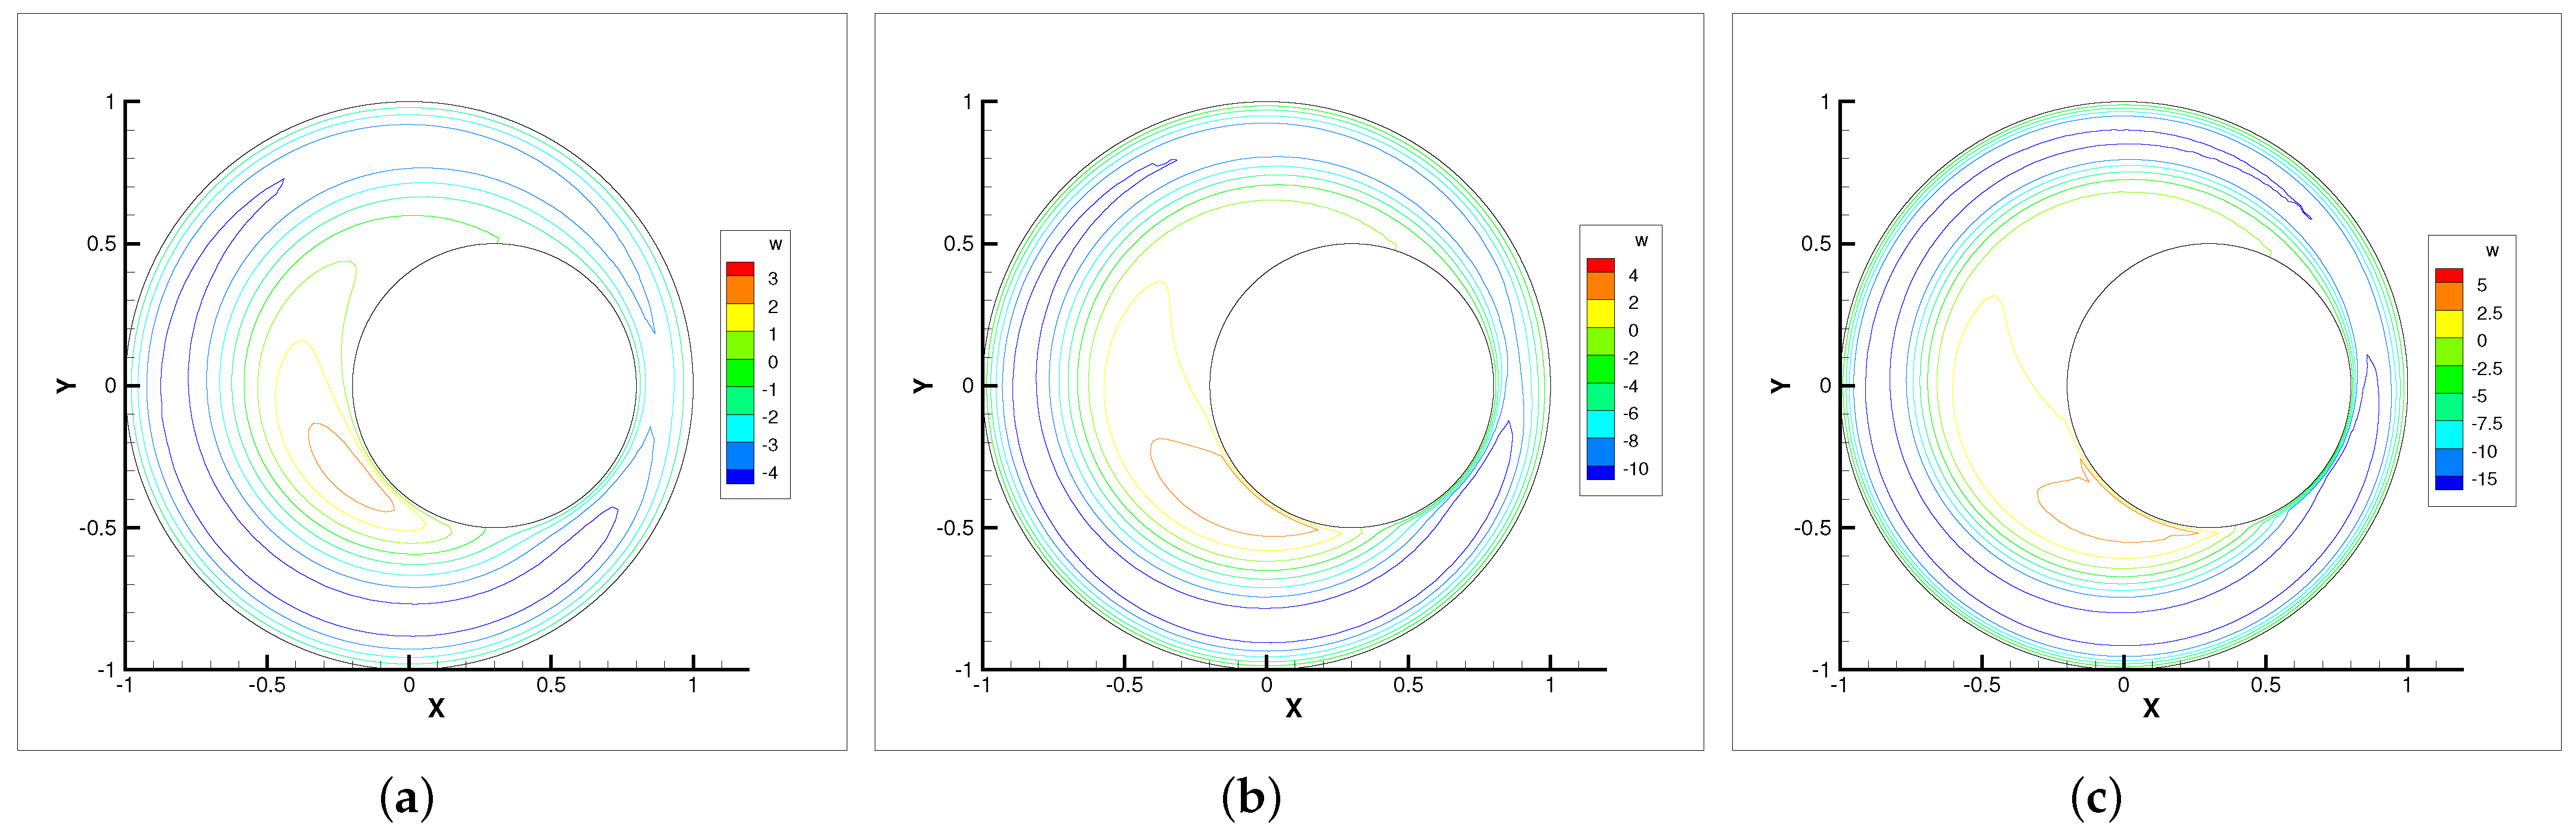
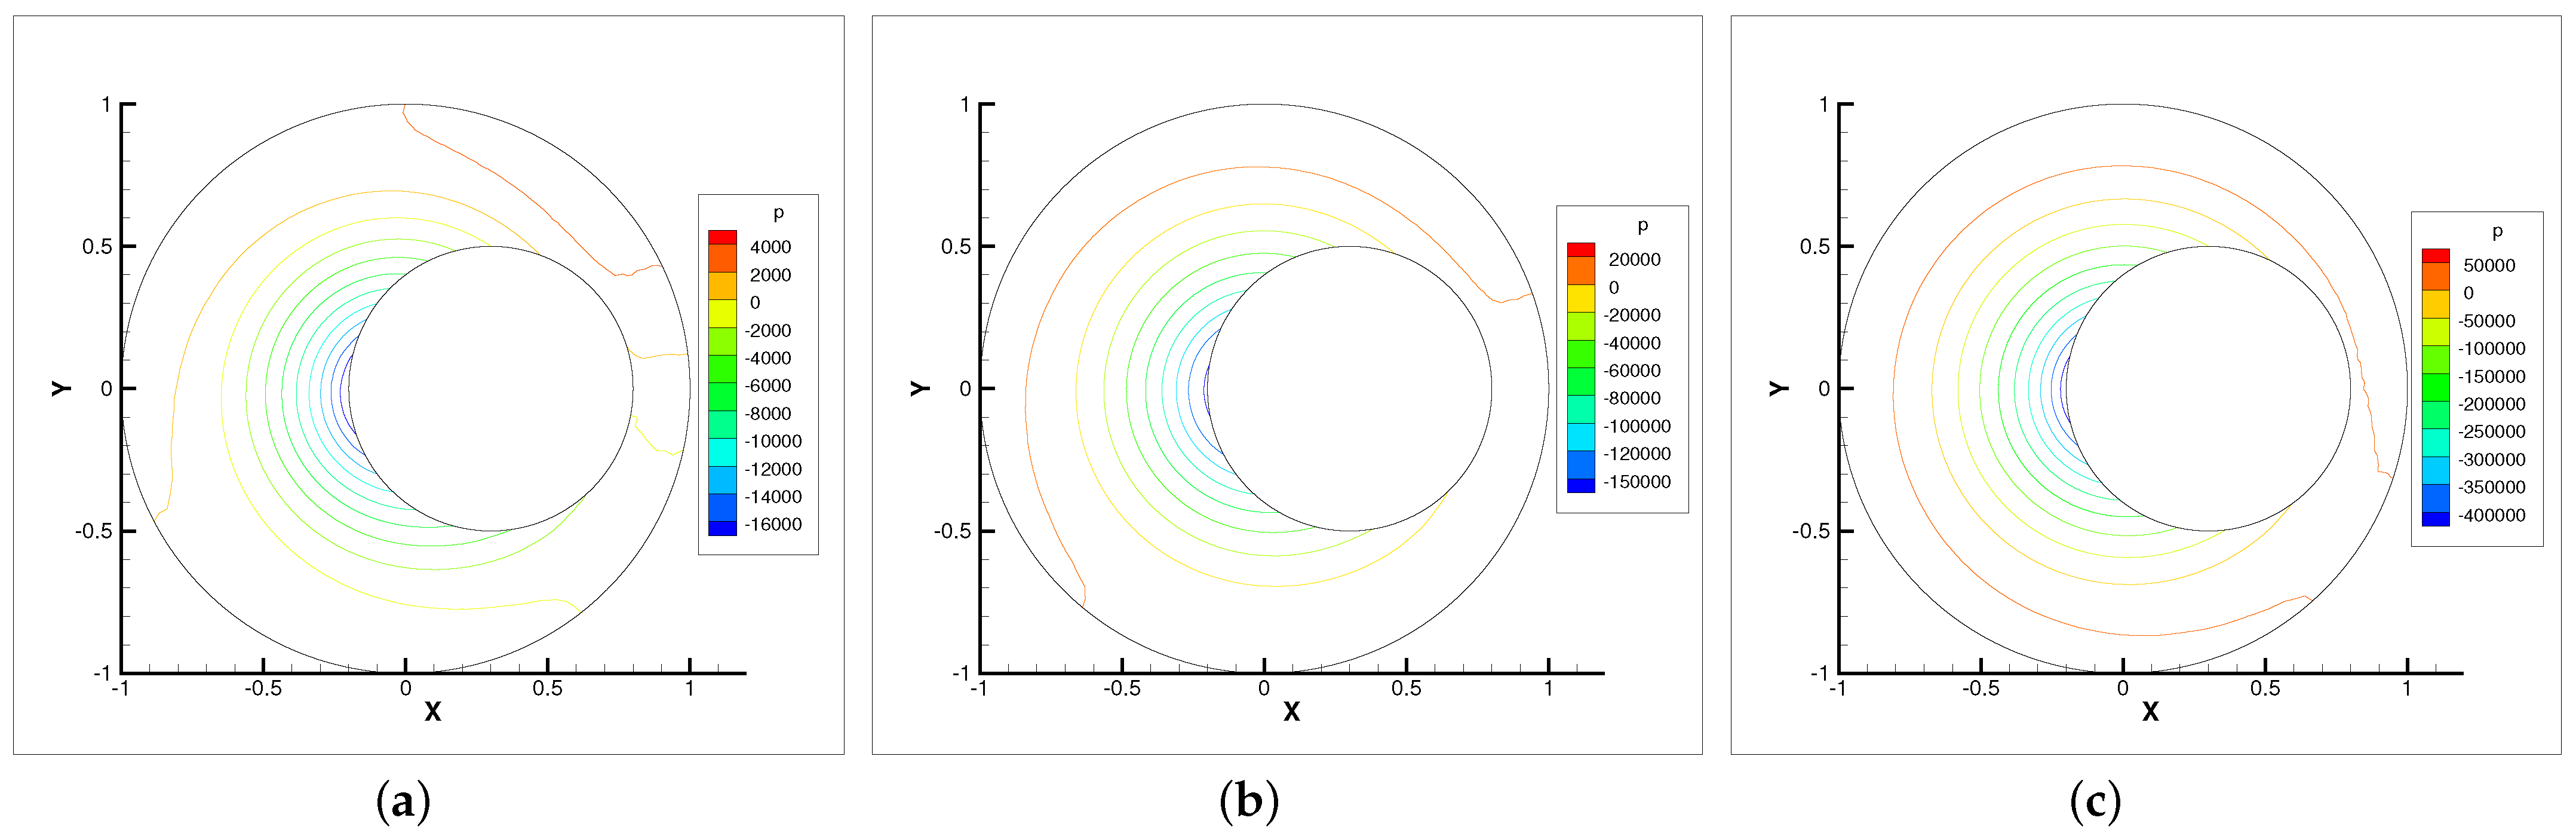
In this example, we only present the numerical experimental results for the Newton iterative method since it is faster than the Stokes and Oseen iterative methods. Figure 5, Figure 6, Figure 7 and Figure 8 show the evolution diagram of velocity components (horizontal velocity, vertical velocity), angular velocity and pressure at three different rotational angular velocities .
Figure 5.
Horizontal velocity contour lines with . (a) . (b) . (c) .
Figure 6.
Vertical velocity contour lines with . (a) . (b) . (c) .
Figure 7.
Angular velocity contour lines with . (a) . (b) . (c) .
Figure 8.
Pressure isobars with . (a) . (b) . (c) .
The numerical results show that the velocity components, angular velocity and pressure increase with the increase in the rotational angular velocity . The pressure increase is the most obvious. Therefore, the bearing is capable of supporting higher loads. The angular velocity contour lines tend to revolve around the inner circle. This means that the higher the rotational angular velocity , the stronger the micropolarity effect of the fluid.
6. Conclusions
In this paper, three iterative methods are analyzed and compared for the micropolar fluid equations. The strong stability conditions for the Stokes and Newton iterations can be determined by the parameter , i.e., and , respectively. Furthermore, the uniqueness condition for the Oseen iterative method is derived. Theoretical results and numerical simulations show that the iterative algorithm for the Stokes iteration is the simplest for larger viscosity coefficients, and the Newton iteration is the most efficient method for relatively large viscosity coefficients. The Oseen iterative method is the most flexible method because its stability and convergence condition is the weakest. Furthermore, the simplified bearing lubrication problem with inhomogeneous boundary conditions is considered and some interesting physical phenomena are observed. In addition, we notice that the results of pressure in the third example are not ideal. In future research, we will consider to improve pressure stability by adding stability terms.
Author Contributions
Formal analysis, X.X. and D.L.; Methodology, X.X. and D.L. All authors have read and agreed to the published version of the manuscript.
Funding
The work is supported by the Research Fund from the Key Laboratory of Xinjiang Province (No.2022D04014), the National Natural Science Foundation of China (Nos.12061075, 12061076) and the Xinjiang Key Laboratory of Applied Mathematics (No.XJDX1401).
Institutional Review Board Statement
Not applicable.
Informed Consent Statement
Not applicable.
Data Availability Statement
Not applicable.
Acknowledgments
The authors sincerely thank the editor and referees for their valuable comments and suggestions which helped us to improve the quality of this paper.
Conflicts of Interest
The authors declare no conflict of interest.
Appendix A
The Proof of Theorem 2.
For Equation (A2), applying the regularity of the Poisson equation and Young’s inequality, we obtain
Appendix B
The Proof of Theorem 4.
On the other hand,
Similarly, the right-hand side of (A6) can be bounded by
Combining the above two inequalities yields
Let in (A5) leads to
With the help of discrete inf-sup condition (22), we obtain
Then, let us prove norm error estimate. Set the dual problem [6,18] as follows: seek such that
If the solution of (A14) satisfies , and , this means that
The proof is completed. □
Appendix C. The Tables of 2D/3D Problems with Exact Solutions
Table A1.
Stokes iterative method for 3D stationary micropolar fluid equations.
Table A2.
Newton iterative method for 3D stationary micropolar fluid equations.
Table A3.
Oseen iterative method for 3D stationary micropolar fluid equations.
Appendix D. The Figures of Triangular Cavity Flow
Figure A1.
Study the geometry (left); Structured grid (right).
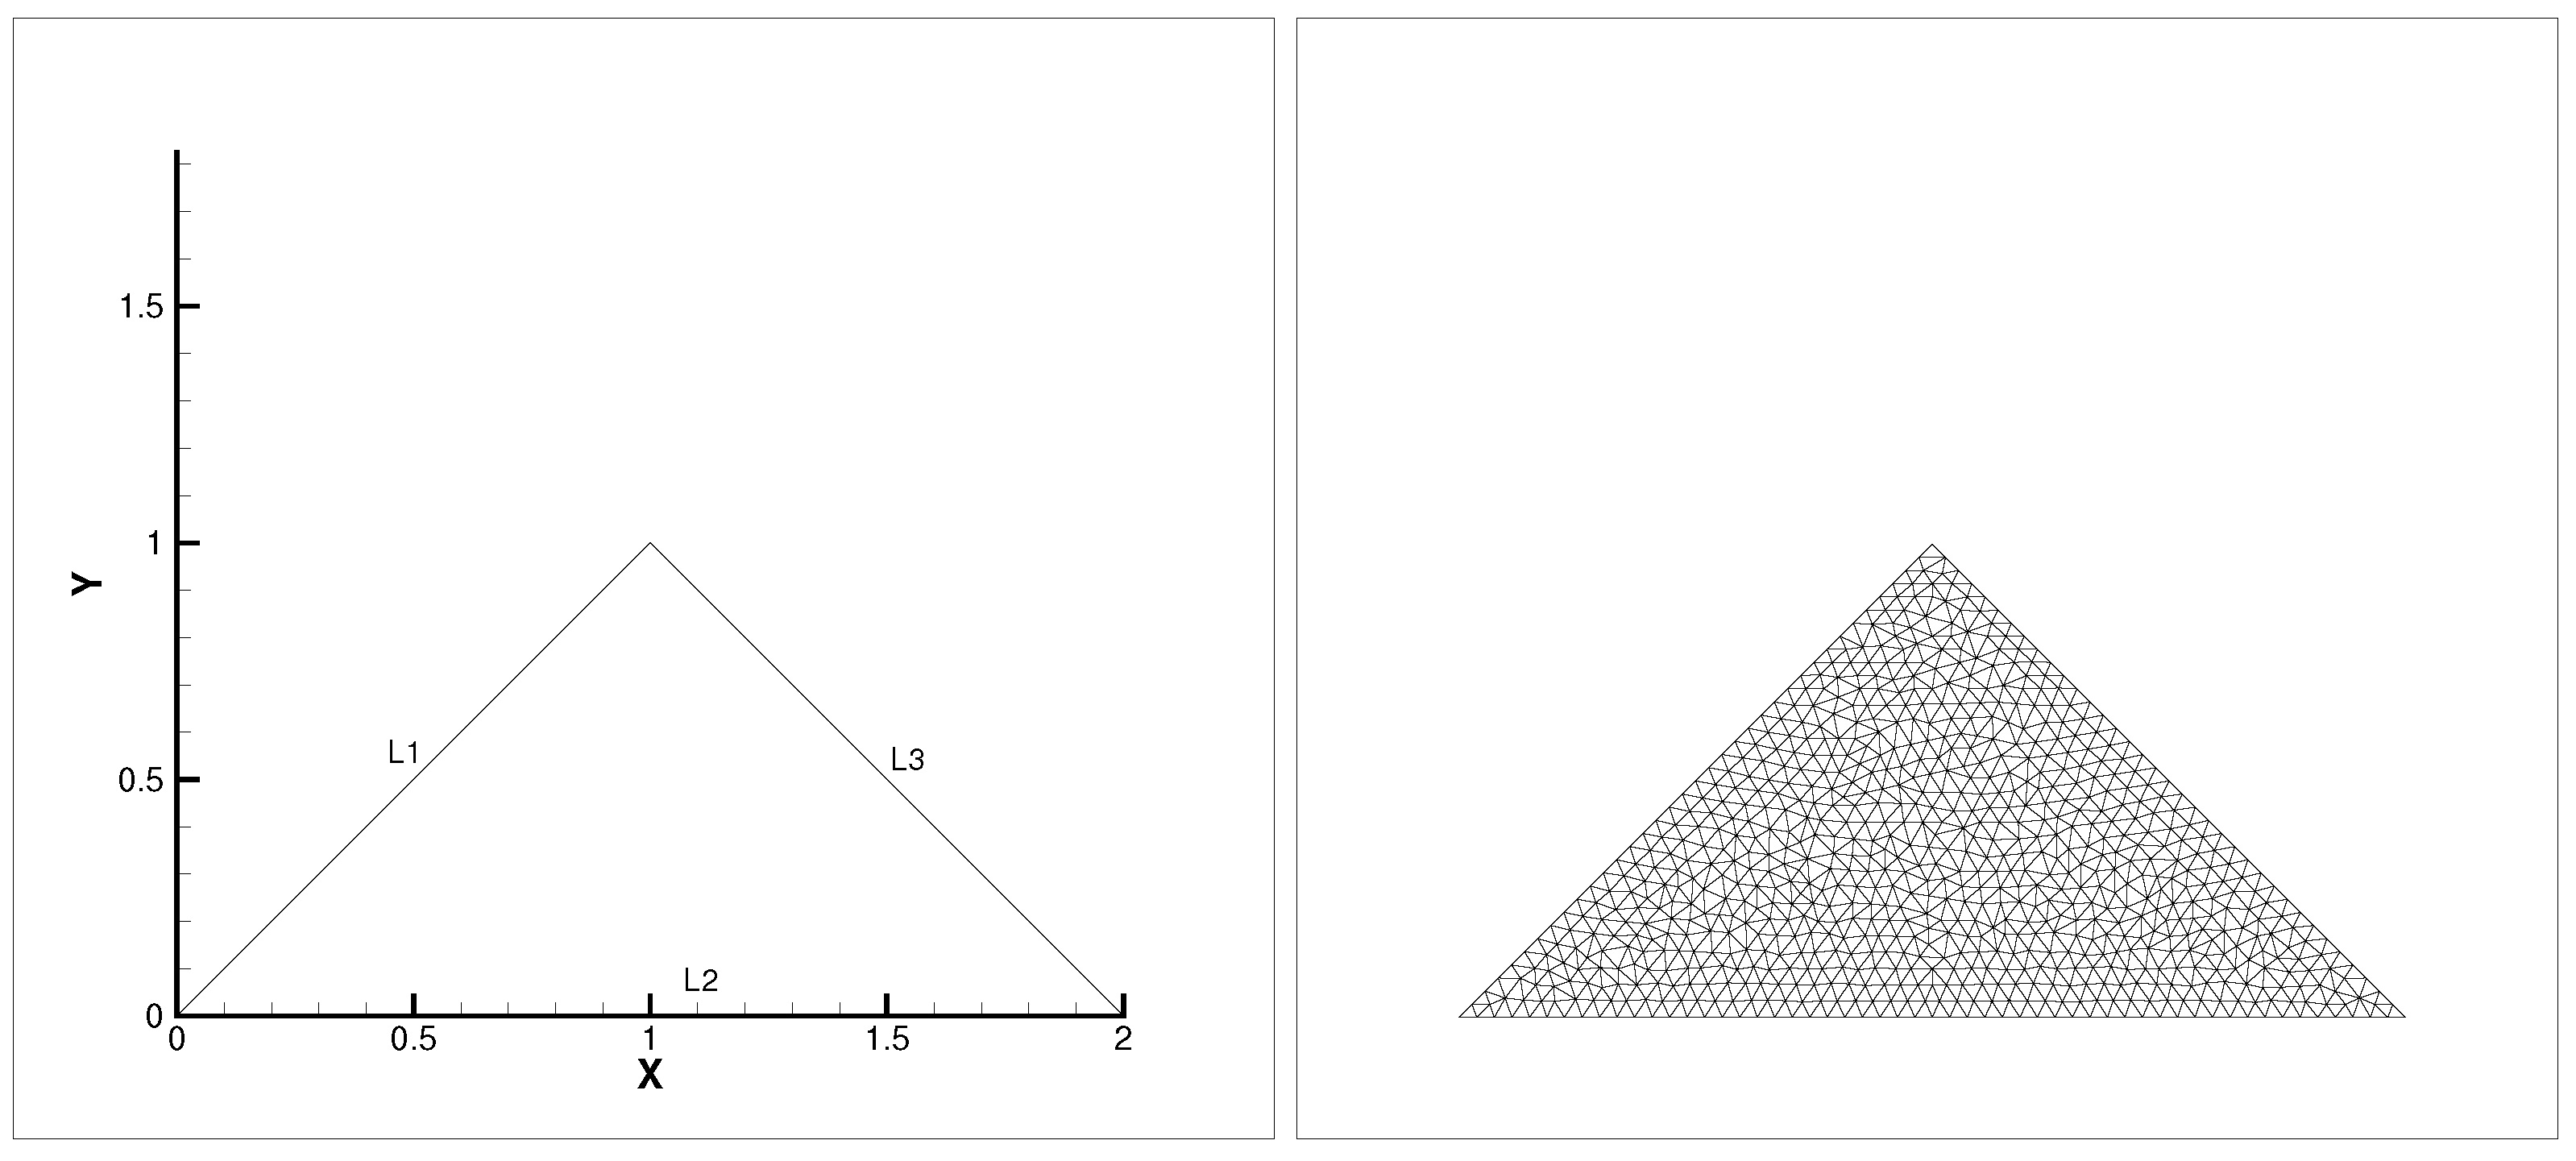
Figure A2.
Velocity streamlines (a), angular velocity contour lines (b) and pressure isobars (c) with .
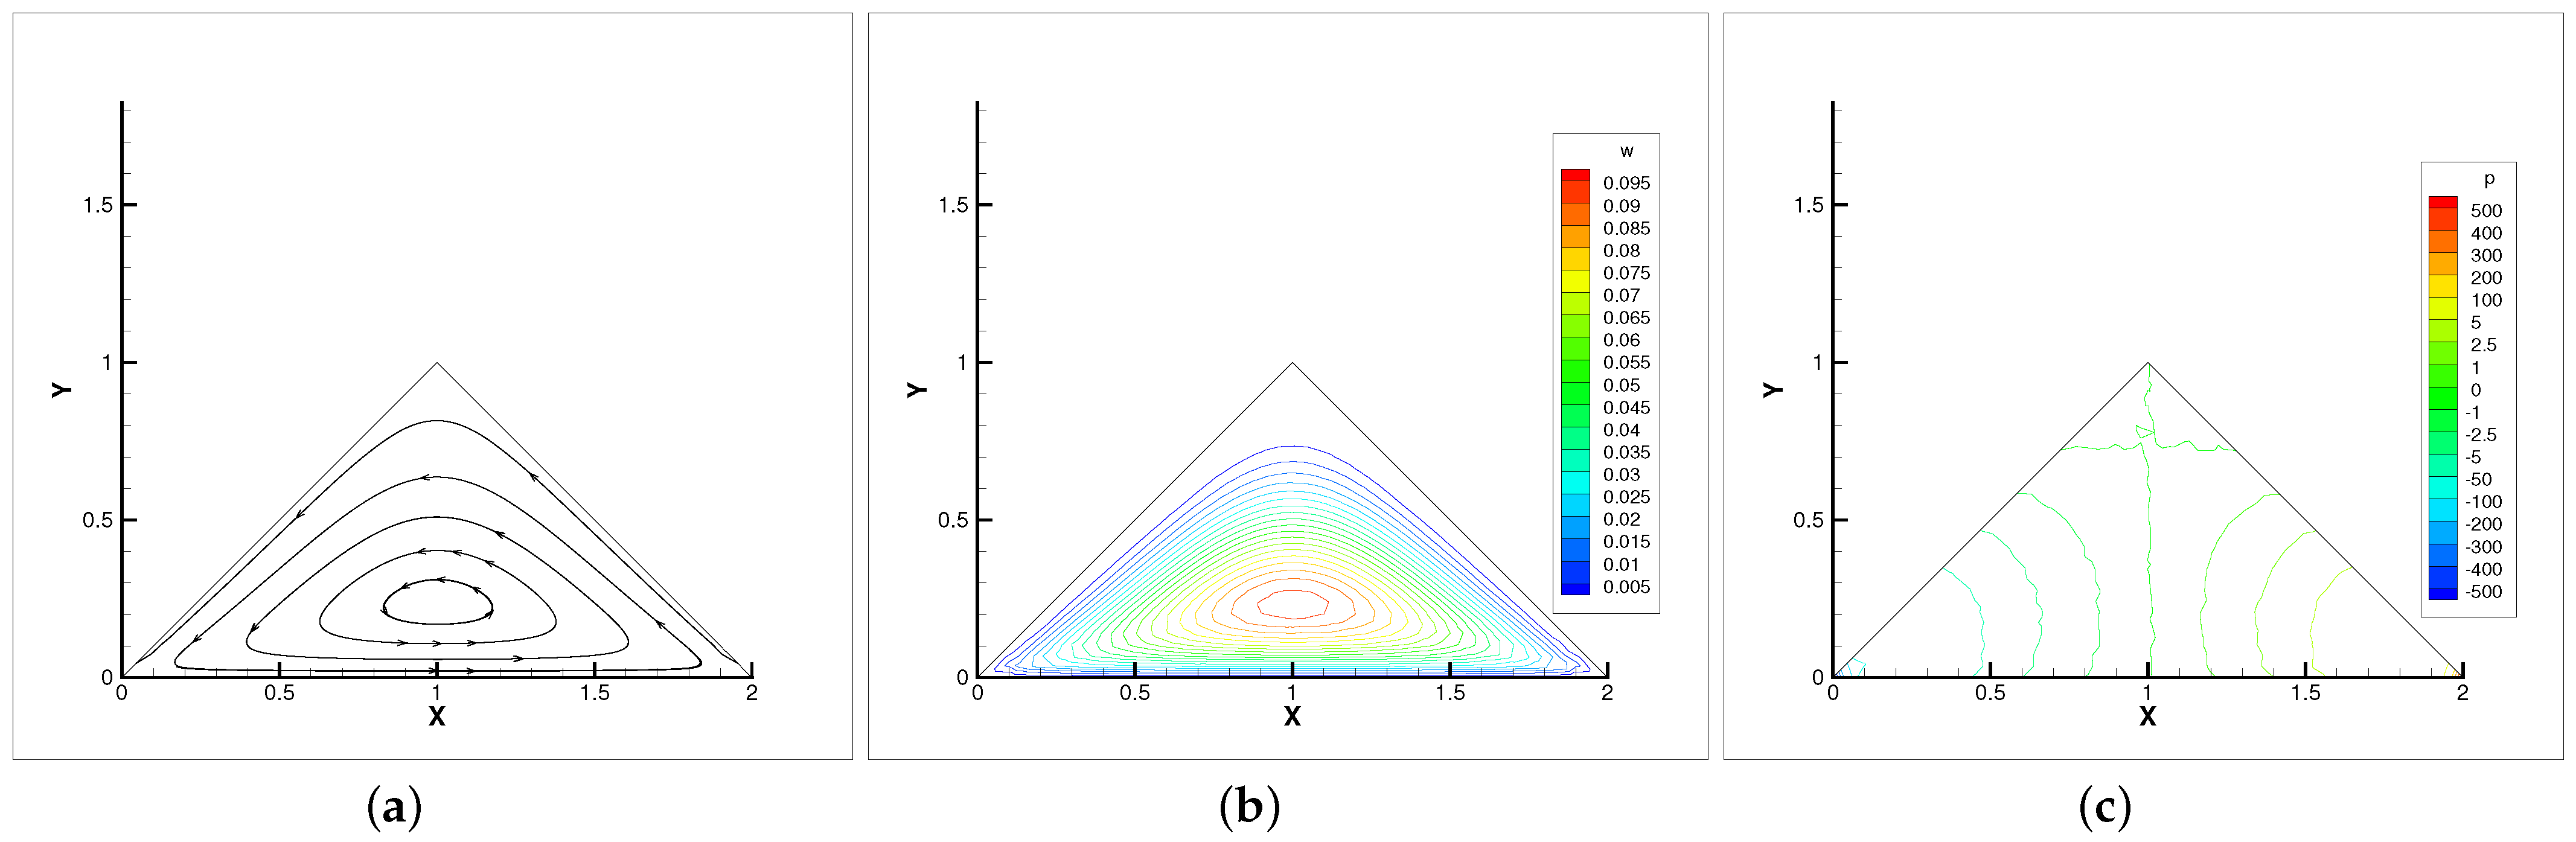
Figure A3.
Velocity streamlines (a), angular velocity contour lines (b) and pressure isobars (c) with .
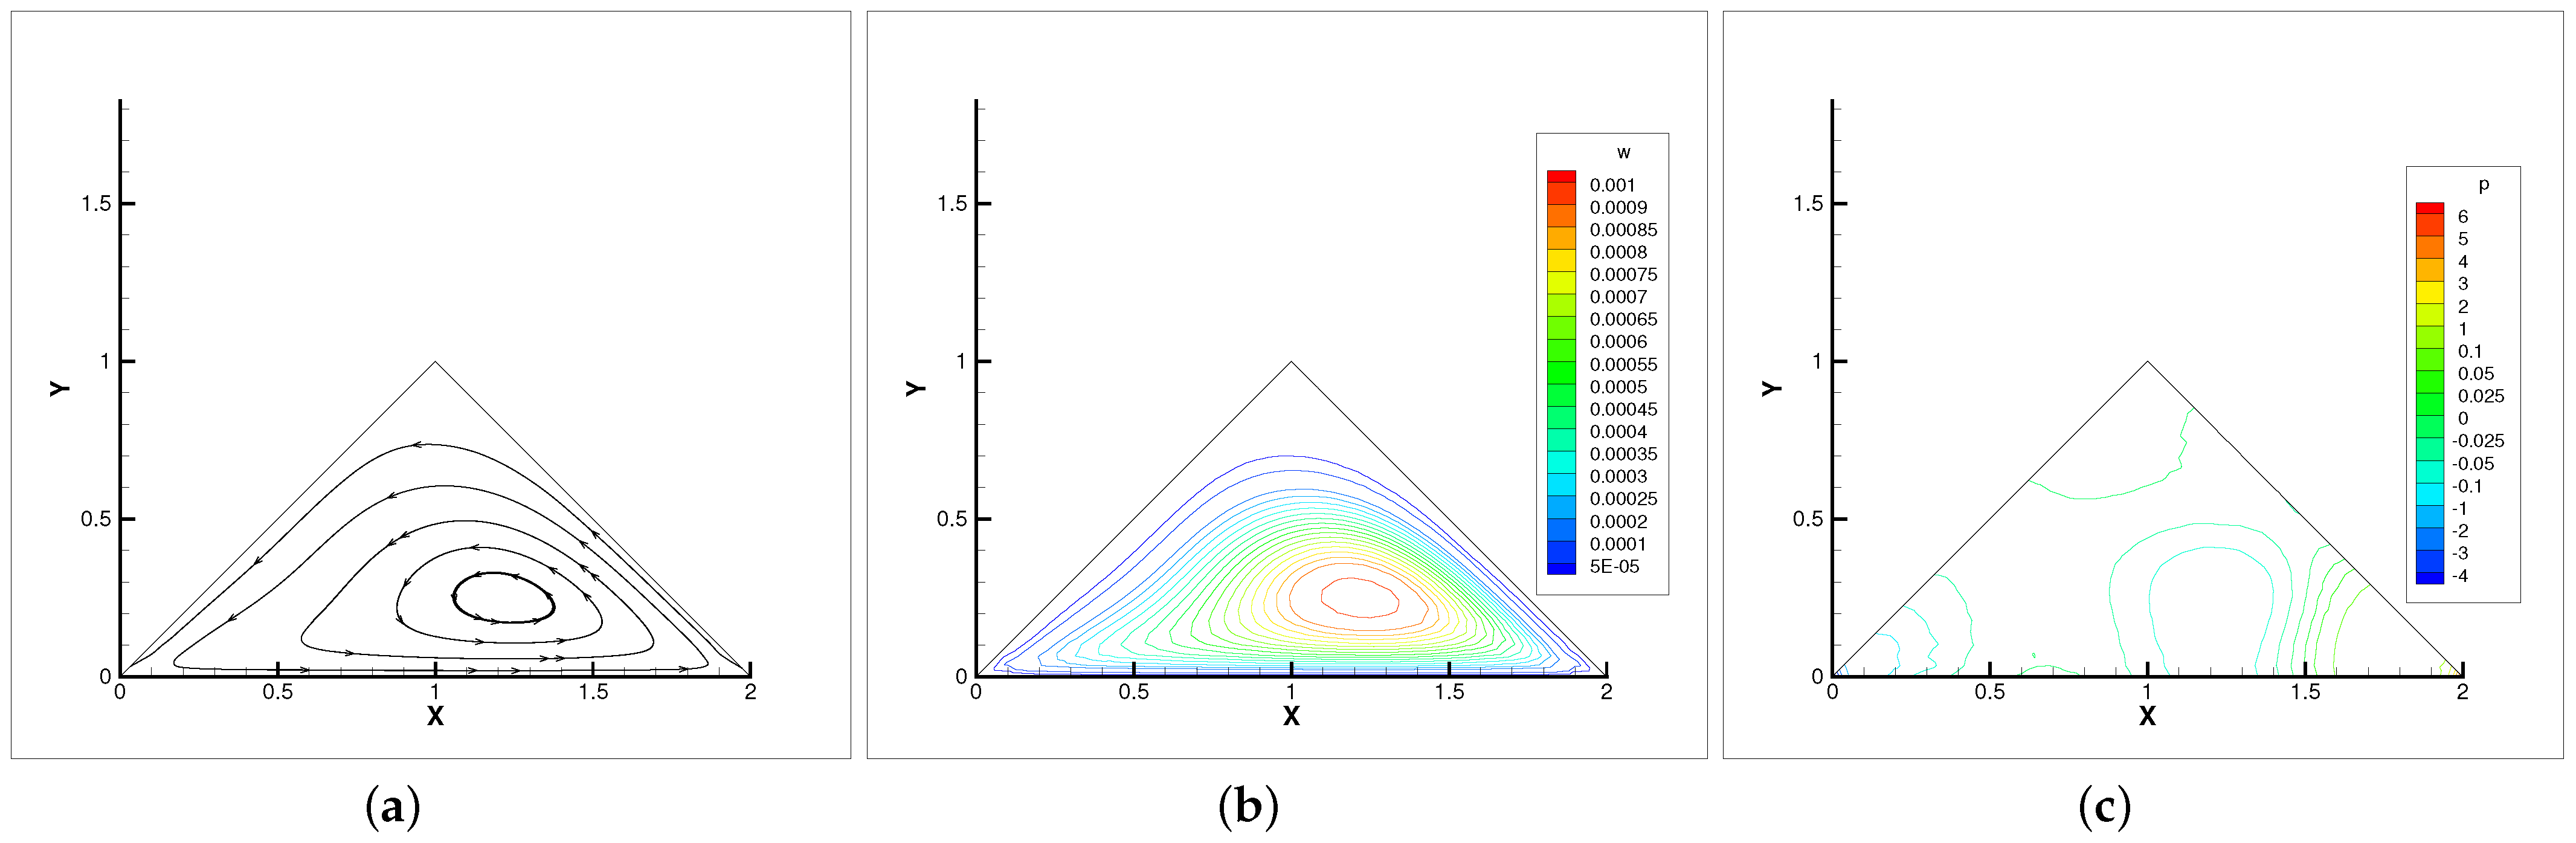
Figure A4.
Velocity streamlines (a), angular velocity contour lines (b) and pressure isobars (c) with .
References
- Eringen, A. Theory of Micropolar Fluids. J. Math. Mech. 1966, 16, 1–18. [Google Scholar] [CrossRef]
- Debnath, L. On a microcontinuum model of pulsatile blood flow. Acta. Mech. 1976, 24, 165–177. [Google Scholar] [CrossRef] [Scilit]
- Abd, E.; Mekheimer, K.; Abdelsalam, S. A Study of Nonlinear Variable Viscosity in Finite-Length Tube with Peristalsis. Appl. Bionics Biomech. 2014, 11, 197–206. [Google Scholar]
- Galdi, G.; Rionero, S. A note on the existence and uniqueness of solutions of the micropolar fluid equations. Int. J. Eng. Sci. 1977, 2, 105–108. [Google Scholar] [CrossRef] [Scilit]
- Rojas-Medar, M.; Boldrini, J. Magneto-micropolar fluid motion: Existence of weak solution. Rev. Mat. Comput. 1998, 11, 443–460. [Google Scholar] [CrossRef] [Scilit]
- Łukaszewicz, G. Micropolar Fluids: Theory and Applications; Birkhäuser: Boston, MA, USA, 1999. [Google Scholar]
- Łukaszewicz, G. On non-stationary flows of incompressible asymmetric fluids. Math. Meth. Appl. Sci. 1990, 13, 219–232. [Google Scholar] [CrossRef] [Scilit]
- Dong, B.; Chen, Z. Regularity criteria of weak solutions to the three-dimensional micropolar flows. J. Math. Phys. 2009, 50, 103525. [Google Scholar] [CrossRef] [Scilit]
- He, Y.; Li, J. Convergence of three iterative methods based on the finite element discretization for the stationary Navier–Stokes equations. Comput. Methods Appl. Mech. Engrg. 2009, 198, 1351–1359. [Google Scholar] [CrossRef] [Scilit]
- Dong, X.; He, Y. Convergence of some finite element iterative methods related to different Reynolds numbers for the 2D/3D stationary incompressible MHD. Sci. China Math. 2016, 59, 589–608. [Google Scholar] [CrossRef] [Scilit]
- He, Y. Euler implicit/explicit iterative scheme for the stationary Navier–Stokes equations. Numer. Math. 2013, 123, 67–96. [Google Scholar] [CrossRef] [Scilit]
- Xu, J. A novel two-grid method for semilinear elliptic equations. SIAM J. Sci. Comput. 1994, 15, 231–237. [Google Scholar] [CrossRef] [Scilit]
- Xu, H.; He, Y. Some iterative finite element methods for steady Navier-Stokes equations with different viscosities. J. Comput. Phys. 2013, 232, 136–152. [Google Scholar] [CrossRef] [Scilit]
- Layton, W. A two-level discretization method for the Navier–Stokes equations. Comput. Math. Appl. 1993, 26, 33–38. [Google Scholar] [CrossRef] [Scilit]
- Layton, W.; Tobiska, L. A two-level method with backtracking for the Navier–Stokes equations. SIAM J. Numer. Anal. 1998, 35, 2035–2054. [Google Scholar] [CrossRef] [Scilit]
- Huang, P.; Feng, X.; He, Y. Two-level defect-correction Oseen iterative stabilized finite element methods for the stationary Navier–Stokes equations. Appl. Math. Mod. 2013, 37, 728–741. [Google Scholar] [CrossRef] [Scilit]
- Galdi, G. Navier–Stokes Equations: A Mathematical Analysis; Springer: New York, NY, USA, 2009. [Google Scholar]
- Girault, V.; Raviart, P. Finite Element Approximation of Navier–Stokes Equations; Springer: Berlin, Germany, 1986. [Google Scholar]
- Liu, Q.; Hou, Y. A two-level correction method in space and time based on Crank–Nicolson scheme for Navier–Stokes equations. Int. J. Comput. Math. 2010, 87, 2520–2532. [Google Scholar] [CrossRef] [Scilit]
- He, Y. Two-level method based on finite element and Crank–Nicolson extrapolation for the time-dependent Navier–Stokes equations. SIAM J. Numer. Anal. 2003, 41, 1263–1285. [Google Scholar] [CrossRef] [Scilit]
- Ortega-Torres, E.; Rojas-Medar, M. Optimal error estimate of the penalty finite element method for the micropolar fluid equations. Numer. Funct. Anal Optim. 2008, 29, 612–637. [Google Scholar] [CrossRef] [Scilit]
- Nochetto, R.; Salgado, A.; Tomas, I. The micropolar Navier-Stokes equations: A priori error analysis. Math. Mod. Meth. Appl. Sci. 2014, 24, 1237–1264. [Google Scholar] [CrossRef] [Scilit]
- Jiang, Y.; Yang, Y. Analysis of some projection methods for the incompressible fluids with microstructure. J. Korean. Math Soc. 2018, 55, 471–506. [Google Scholar]
- Maimaiti, H.; Liu, D. Pressure-correction projection methods for the time-dependent micropolar fluids. Int. J. Numer. Meth Fluids. 2021, 94, 377–393. [Google Scholar] [CrossRef] [Scilit]
- Adams, R. Sobolev Space; Academic Press: New York, NY, USA, 1975. [Google Scholar]
- FreeFem++, Version 4.5. 2020. Available online: http:www.freefem.org/ff++/ (accessed on 1 September 2021).
- Ghia, U.; Ghia, K.; Shin, C. High-Re solutions for incompressible flow using the Navier-stokes equations and a multigrid method. J. Comput. Phys. 1982, 48, 387–411. [Google Scholar] [CrossRef] [Scilit]
- Ali, N.; Mubbashar, N.; Javed, T.; Abbas, F. A numerical study of micropolar flow inside a lid-driven triangular enclosure. Meccanica 2018, 53, 3279–3299. [Google Scholar] [CrossRef] [Scilit]
- Prakash, J.; Sinha, P. Lubrication theory for micropolar fluids and its application to a journal bearing. Int J. Eng. Sci. 1975, 13, 217–232. [Google Scholar] [CrossRef] [Scilit]

Publisher’s Note: MDPI stays neutral with regard to jurisdictional claims in published maps and institutional affiliations. |
© 2022 by the authors. Licensee MDPI, Basel, Switzerland. This article is an open access article distributed under the terms and conditions of the Creative Commons Attribution (CC BY) license (https://creativecommons.org/licenses/by/4.0/).