


Abstract
The main goal of this study is to improve the performance of laser rotating of non-contact human body scanning system, and to get the true and accurate 3D information of measured human body. In the aspect of obtaining the human body pixel coordinates, the extraction accuracy of laser stripe center is one of the important factors to affect the measurement accuracy. Therefore, this paper mainly discussed the algorithm of obtaining and the curve fitting human body scanning laser stripe center pixel coordinates. In the analysis of the characteristics of the human body laser stripe images, put the improved column processing algorithm to compute stripe center position. Using the Bezier curve fitting of the human body scanning light trap center line, effectively improved the smoothness of the human body scanning light trap center line.
1. Introduction
CCD camera collecting the human body laser stripe images is based of rotary 3D body scanning system that is based on structure of optical visual measurement [1]. The quality of human body laser stripe images and the processing algorithm is correct or not directly affect the system scanning precision [2,3]. In order to meet the accuracy requirement of the system of scanning, the human body laser stripe images have to be complete the following steps: (1) pre-processing; (2) the extraction of laser light center pixel coordinates; (3) the curve fitting of the center line of human body scanning laser light, etc. Through the reasonable algorithm, the laser light band width of more than one pixel has developed into complete, single pixel of human body center laser line, which met the requirements of the subsequent of three dimensional human body coordinates reconstruction. Because the characteristics of laser stripe images to the pre-treatment, extraction and curve fitting of laser light center position and so on, all have higher requirements [4,5,6].
This paper’s main goal is to improve the measurement performance basing on structure light vision of rotary 3D body scanning system, measures the body, get true and accurate threedimensional coordinate information, so this paper from the subject of the second step, the laser stripe image data processing technology, the system to the human body laser stripe image pixel coordinates calculate methods for special treatment and research.
In pixel coordinates calculating, the extraction accuracy of human body laser light center pixel coordinates is one of the important factors that affect measuring precision [7], and the camera discrete pixels can cause human body surface originally a smooth band becomes not smooth [8,9]. Therefore, this paper focuses on the two parts of algorithm, first is after analysis the characteristic of human body laser stripe images, a column processing algorithm is proposed to calculate human body center of the laser light; second, in the case of the images on the border between the cameras as sensitive unit, with the Bezier curve fitting body scanning laser light center line, effectively improved the body scan, the smoothness of the center line of the laser light.
2. Characteristic of Human Body Laser Stripe Images
By using a three-dimensional structured light vision measurement principle as well known [9], the depth parameter of this study is determined by the measured human body laser stripe pixel coordinates in the camera position. Laser stripe shapes that camera received were varied with the transformation of human body’s surface situation.
According to the characteristics of laser stripe images, the human body laser stripe images whose acquisition was based on the laser stripe rotating 3D human body scanning system usually has the following characteristics:
- 1)
- Most of the human body laser stripe images are simple stripe images. These images usually have one or more smooth stripes. That is to say, there are one or more continuous laser stripes in one human body image. These simple laser stripes appear in the relatively flat surface region of the human body, such as the position of neck region, the position of back or shoulder and so on.
- 2)
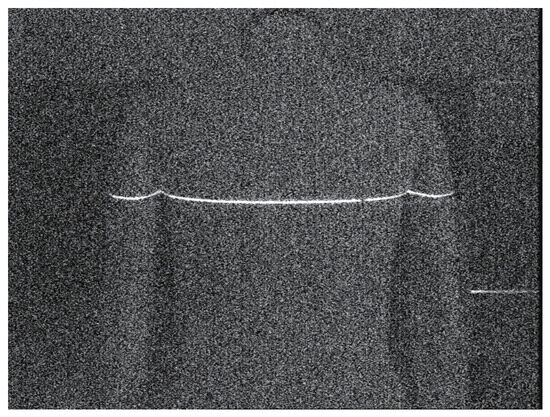
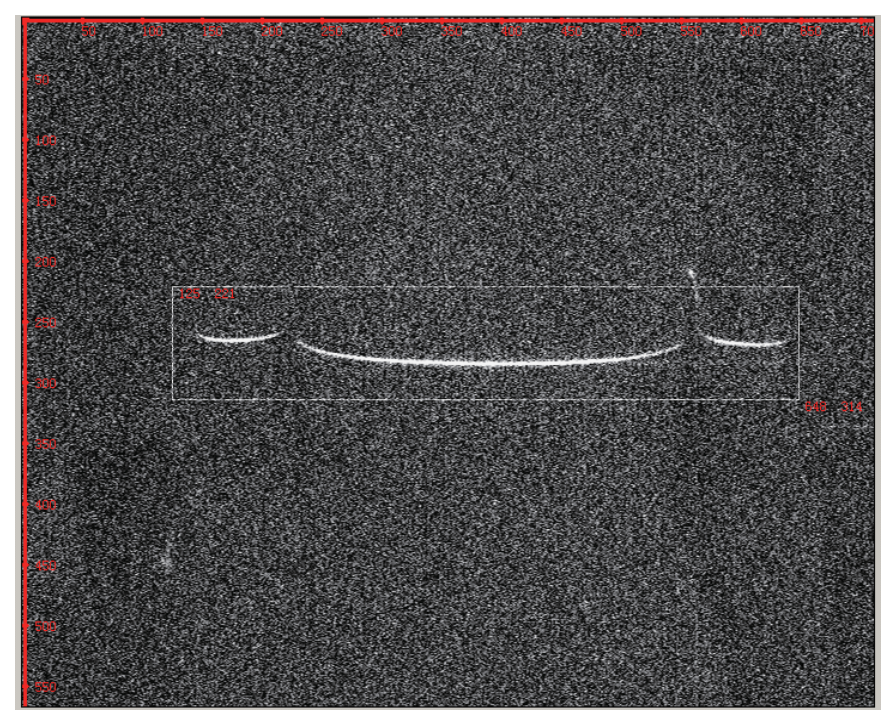
- Because of the human body are measured by natural standing posture, when the laser stripe is located at the position of the torso, both side of the arms images will be obtained. Usually, these images have one or more segment of laser stripes, and these stripes cannot overlap. For example, the laser stripe image of human body’s back is shown in Figure 1, it can be seen from Figure 1 that the optical laser stripe consists with three parts, namely, the left arm laser stripe, torso laser stripe and the right arm laser stripe.Figure 1. Laser stripe images of human back position.
3. The Extraction of Human Body Laser Stripe Center Pixel Coordinates
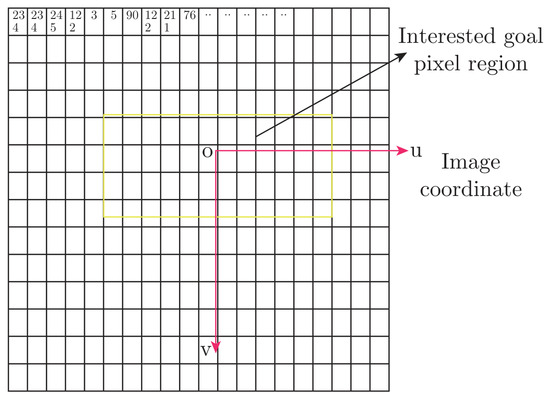
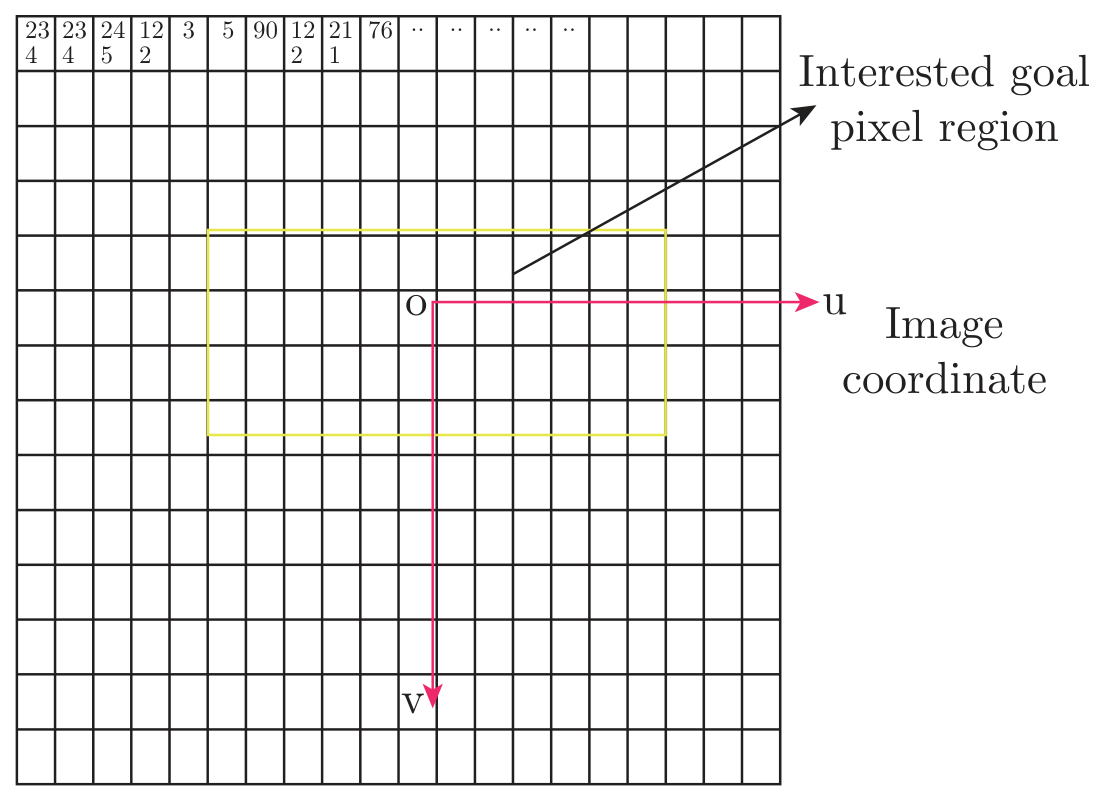
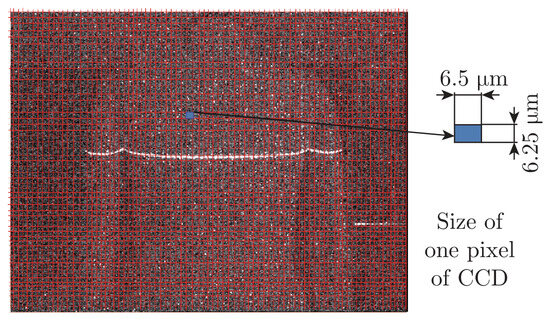
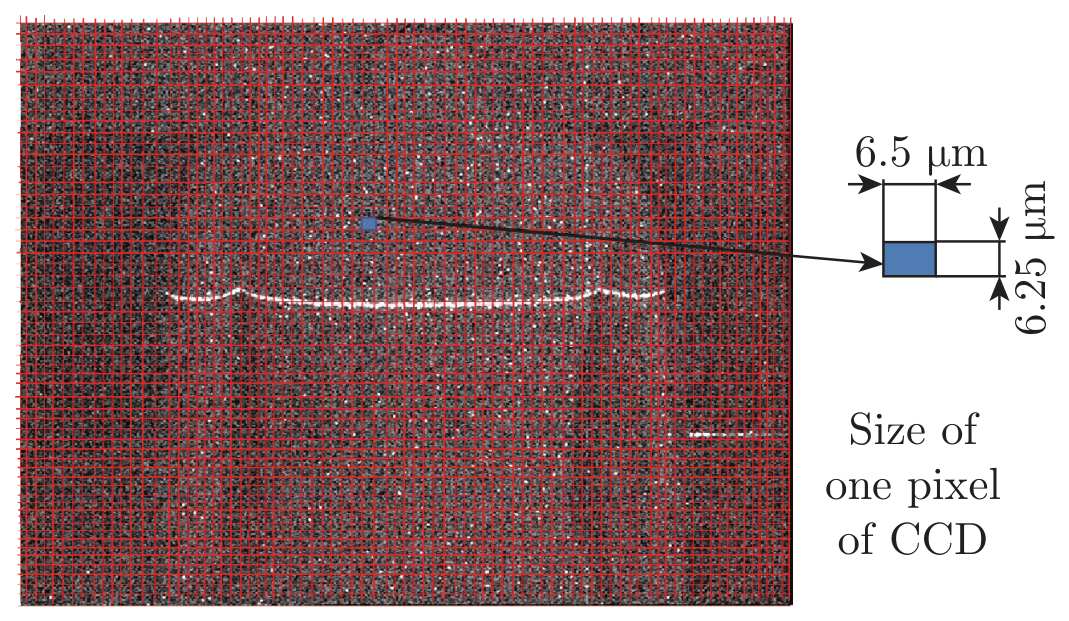
The accuracy of the extraction of human body laser stripe center pixel coordinates is one of the most important factor, that affects the accuracy of this scanning measurement. This paper mainly studies the extraction of human body laser stripe center pixel coordinates, which was based on the structure light vision of rotary 3D human body scanning system. The definition of image pixel coordinate system is shown in Figure 2. In Figure 2, the row direction of the image is u coordinate. The right direction of u is positive direction. The column direction of the image is v coordinate. The downward direction of v is positive direction. The units of the image pixel coordination are shown in Figure 3. The size of one pixel of CCD can be seen from Figure 3. The row size of one pixel of CCD is 6.5 um. The column size of one pixel of CCD is 6.25 um.
Figure 2.
The definition of image pixel coordinate system.
Figure 3.
Size of one pixel of CCD.
The operation method of the structure light vision of rotary 3D human body scanning system is shown as follows [10,11]: A line laser emission emitted a laser beam. After the laser beam passed through a cylindrical lens, it is expanded into a continuous laser plane. The continuous laser plane has certain thickness. The crossing curve between the continuous laser plane and the human body surface is the laser light of a certain width line, called structure light laser stripe.
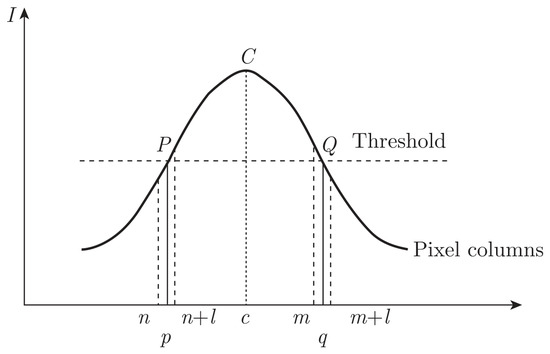
Figure 4 shows the cross section intensity distribution of ideal laser stripe. The distribution is the Gauss distribution. In this distribution diagram, the C which has the greatest intensity value indicate the center of the laser stripe. The algebraic expression of Gauss curve is shown as follows [12,13]:
Figure 4.
Gauss distribution sketch map of ideal laser stripe image.
While A represents the height of the curve amplitude; δ represents the span of the standard deviation curve; u is the average value. By using this extraction algorithm, the accurate position of center of laser light (the C point position) can be found.
The extraction algorithm steps of the human body laser stripe center pixel coordinates are shown as follows:
① Inputs the first frame of image. The specification of the image is BMP file.
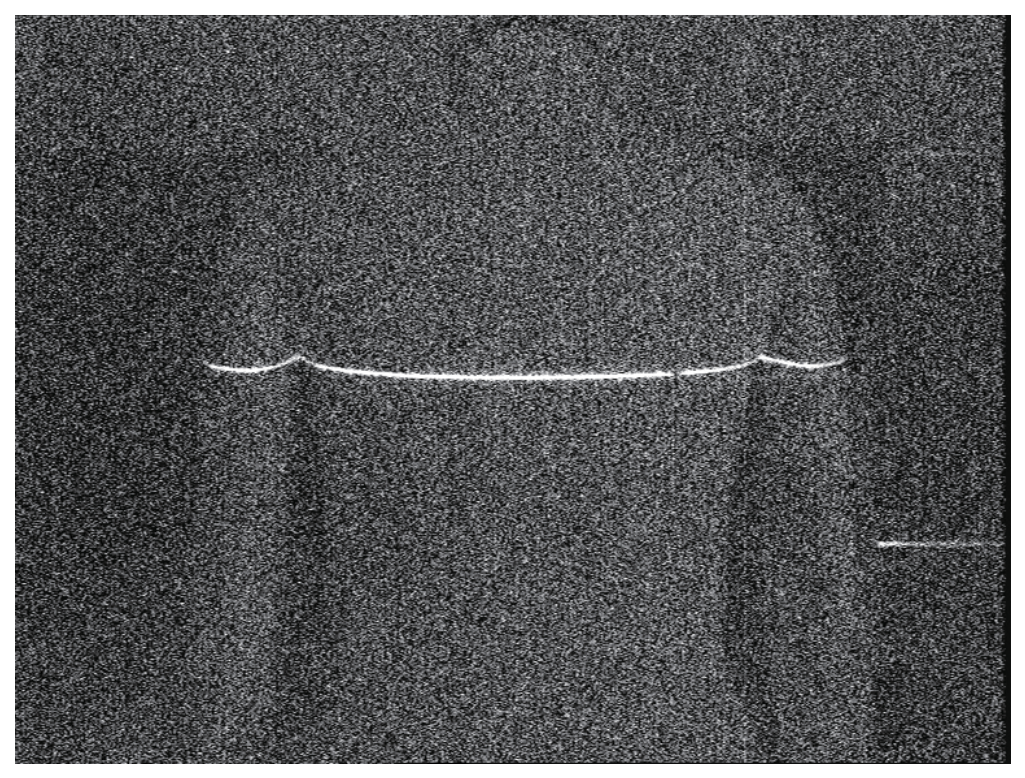
② Selects a sub-image from the BMP image file, which contains the target light (the human body laser stripe), as shown in Figure 5. Through this step, the processing area of the original BMP image is reduced, which becomes more convenient to handle.
Figure 5.
Selection a target sub-image which contains the human body laser stripe.
③ Read grey value of the sub-image file, which contains the target data information (including the human body laser stripe). That is to say, under the guidance of the target human body laser stripe, the coordinate information data of the crossing curve exists in a TXT file.
④ Noise removal. The noise of the structure light vision of rotary 3D human body scanning system is random, and it can not repeat. Therefore, the extraction error of the human body laser stripe center pixel coordinates belongs to the random error. In order to improve the extraction accuracy of the human body laser stripe center pixel coordinates, the influence of random noise must be eliminate. It can be seen from Figure 5, the human body laser stripe is relatively lighter than the other area of the image. The gray value of the human body laser stripe is relatively larger than the gray value of the background. The noise gray value of the background is smaller than the human body laser stripe. So the gray values are easy to distinguish.
In this paper, the median filtering method is used to pre-process the sub-images. Considering the factor of window size of median filtering affects the calculation, the speed of filter processing, the smooth degree of human body laser stripe and the missing gray value information of it, the 3 × 3 window size of median filtering is selected for pre-processing sub-images. In this paper, noise removal is confirm by the following steps: Setting a gray threshold (It); In sub-images, the gray threshold of I(i,j) hasn’t a fixed value, and it is greater than 0 and less than 255, that is 0 ≤ I(i,j) ≤ 255.
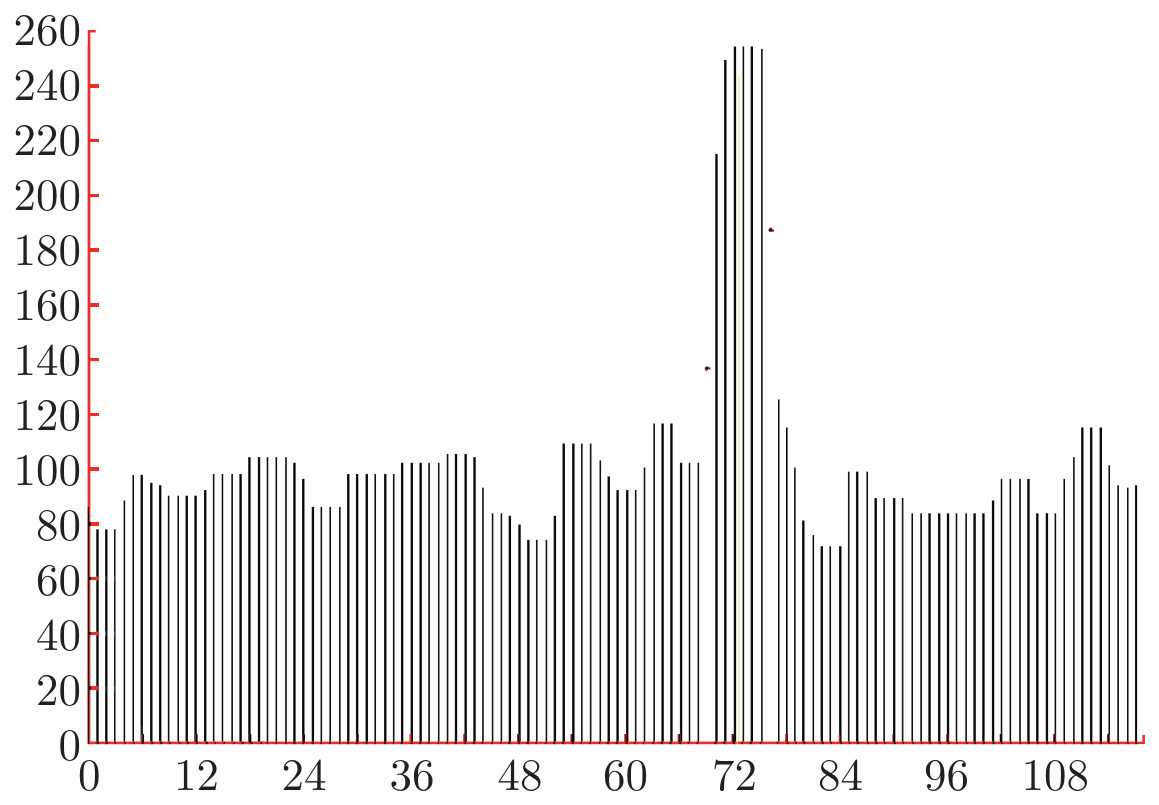
In this process, considering the brightness of the human body laser stripes, and according to many experiments, generally, the value of It can be set between 160 and 220, that is 160 ≤ It ≤ 220. Figure 6 shows a column of gray distribution histogram of a human body laser stripe image. Each I(i,j) of column of gray threshold in sub-image compares with It, according to the equation (2) [14], can not only filter out noises, but also preserve gray value of human body laser stripe pixels.
Figure 6.
A column of gray distribution histogram about human body laser stripe image.
Among them, i = 1, 2, 3, ···, M, j = 1, 2, 3, ···, N, besides the value of M and N are the number of row and column of a image.
⑤ Image gray-scale binary. After de-noising processing, all the pixels of de-noising image are useful. For the convenience of subsequent calculation, in de-noising image, we select the minimum gray threshold as th. The processes of binarization conversion use the following Eq. (3) [15]:
⑥ Calculate the up and down band position of human body laser stripe. For the binarization image, all the gray value of the human body laser stripe pixels is 1. The gray value of other background pixels is 0. In this case, reading each column of a image, calculate the value of image gradient G. In each column of a image, using Eq. (4), the value of G have two values: 1 and 0.
G[I(x,y)]≅|I(x,y) − I(x,y + 1)|
When the gray value of the odd number is 1, which indicates that these positions are up edges of the human body laser stripe, so we mark these positions as dk. When the gray value of the even number is 1, which indicates that these position are down edges of the human body laser stripe and mark these position as uk. So all the up and down edge position of human body laser stripe can be obtained, named [dk,uk], while k = 1,2,3,··· is the number of human body laser stripe.
⑦ Measure the center of human body laser stripe. For each value of [dk,uk], using its up edge position minus its down position, which means calculate the value of t, t = uk −dk. The position of half of t is the human body laser stripe center.
⑧ Determine the number of images that will be disposed. Thus the processing of the extraction of human body laser stripe center pixel coordinates can be finished.
4. Curve Fitting of Human Body Laser Stripe
The extraction error of human body laser stripe center pixel coordinates can be attributing to the following aspects: 1) The influence of pixels on the edge has not been considered, which makes the estimated value inexactly. 2) For the feature of human body surface, the human body laser stripe should be a smooth curve. But due to the discrete pixels of the CCD camera, the smoothness of the human body laser stripe is not very well.
For the research of the system, the more important thing is the constructing curve must reflect the overall shape of human body data points, rather than to satisfy each human body data points.
From what has been discussed above, the method of Bezier curve fitting of human body laser stripe in this study is applied.
The purpose of curve fitting of human body laser stripe center is to eliminate the influence of discrete pixels. Curve fitting can distinguish the position of point which locates in the middle of two pixels. Curve fitting make the human body laser stripe smooth. And the most important thing is the shape of the original human body laser stripe remains unchanged. Since if the feature of human body laser stripe has changed, curve fitting will become meaningless. It is important to make sure that the main feature of the human body laser stripe curve remains unchanged.
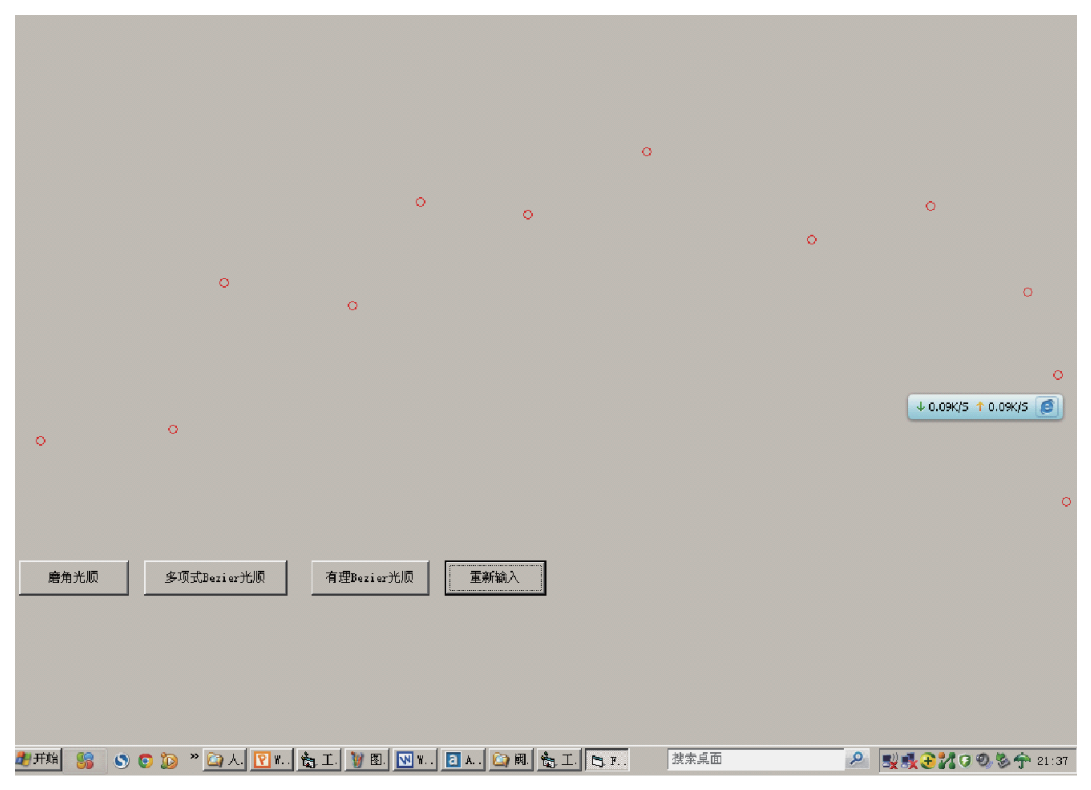
Through the previous section of extraction algorithm of the human body laser stripe center pixel coordinate, we have got the human body laser stripe center pixel coordinates, as shown in Figure 7. In order to achieve a uniform curve fitting of all the human body scanning laser stripes, we should make a section of these cloud data points of the human body. By separating different parts of the data points, we can avoid that the curve fitting is not in conformity with the actual human body feature. Therefore the correctness of the segmentation is the key to ensure the rightness of curve fitting.
Figure 7.
The center pixel coordinates of human body laser stripe.
From the front algorithms of human body laser stripe center pixel coordinates, we know that if we want to calculate a two-dimensional digital image, we should make a traversing of each column of an image. When a column with multiple effective data points, the pixel coordinates will be repeated in the u direction, its corresponding pixel coordinates of the v direction will be have a larger interval.
Through the above analysis, this paper identified a new method of data section which according to the adjacent of cloud data points. The specific steps of the new method of data section are shown as follows:
Through the pixel coordinates of the u direction, we calculate the difference (∆u) of adjacent pixel coordinates. For the judgment of the u direction, we should select a distance threshold (XM) according to the actual situation of a image. The judgment method of the u direction is shown as follows:
① If ∆u ≥ XM, which means the human body laser stripe appear the interrupt, it needs to be segmented.
② If ∆u is other value, the human body laser strip doesn’t need be segmented.
Through the pixel coordinates of the v direction, we calculate the difference (∆v) of adjacent pixel coordinates. For the judgment of the v direction, we should select a distance threshold (Y M) according to the actual situation of a image. The judgment method of the v direction is shown as follows:
① If ∆v ≥ Y M, which means the human body laser stripe appear the interrupt, it needs to be segmented.
② If ∆v is other value, the human body laser strip doesn’t need be segmented.
After segmentation in the accordance with the principle of the above judgment, we can obtain the groups of control vertexes of human body laser stripe. In each group, the Bezier curve is adopted to improve the curve fitting. Based on the number of data points, each segmented basis function select the adapted “n” times in the form of the Bezier curve, as shown in Figure 8. In order to maintain the number of original curve data points, the x coordinate of the original data points remains the same. Then we calculate the function value of y′ at the place of x in a curve. We make y′ as a new ordinate replace the original one. The above process could complete the curve fitting of human body laser stripe.
Figure 8.
Curve fitting of the human body laser stripe.
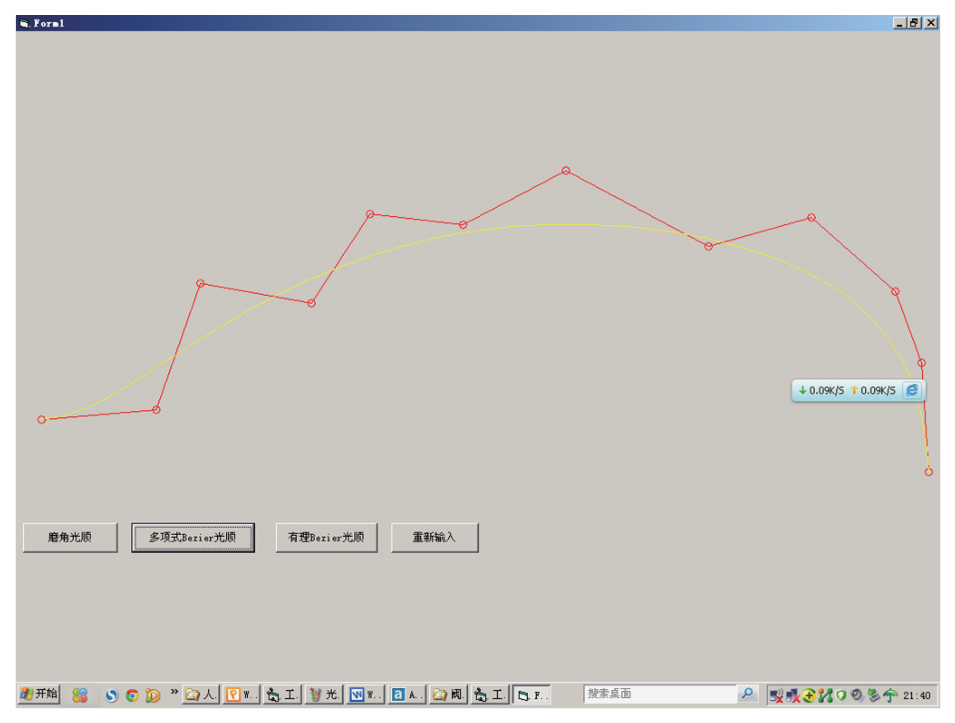
Figure 9.
Curve fitting result of the human body laser stripe.
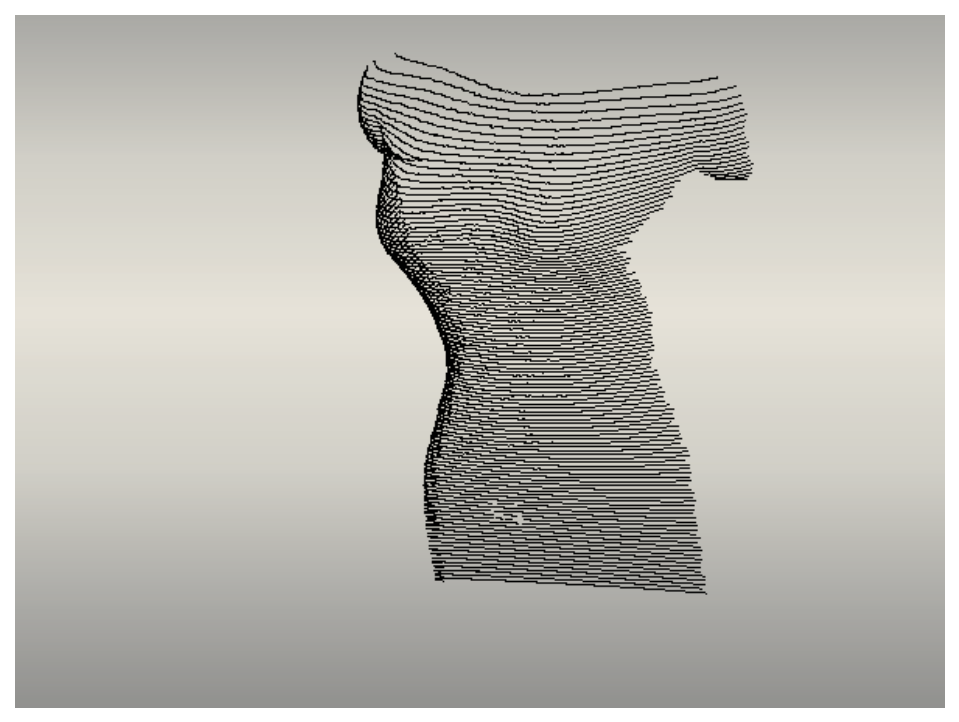
In the process of the curve fitting, the correctness of the number of control points is playing a very important role. The number of the control points determines the shape of the curve. The less the control points are, the better of the original curve characteristics remain. In this situation, a smooth curve can be obtained. But the accuracy of curve fitting is lower. Conversely, the more the control points are, the higher precision can be obtained. In this situation, the curve fitting will be more smoothly. However, the curve feature of the sharp points becomes flat. In this study, after lots of experiments show that the control points of the curve fitting of the human body laser stripe should be not less than 5. Since the condition of the number of control points is less than 5, these points are considered as noise points.
From the above results, we can find out that the curve fitting method discussed in this paper can be used to correctly handle the human body laser stripe center line. We can obtain the human body laser stripe center line, which is in accordance with the original curve shape. Meanwhile, most of the curves become smoother than before. It has proved that the validity of the section method and the effectiveness of the curve fitting method.
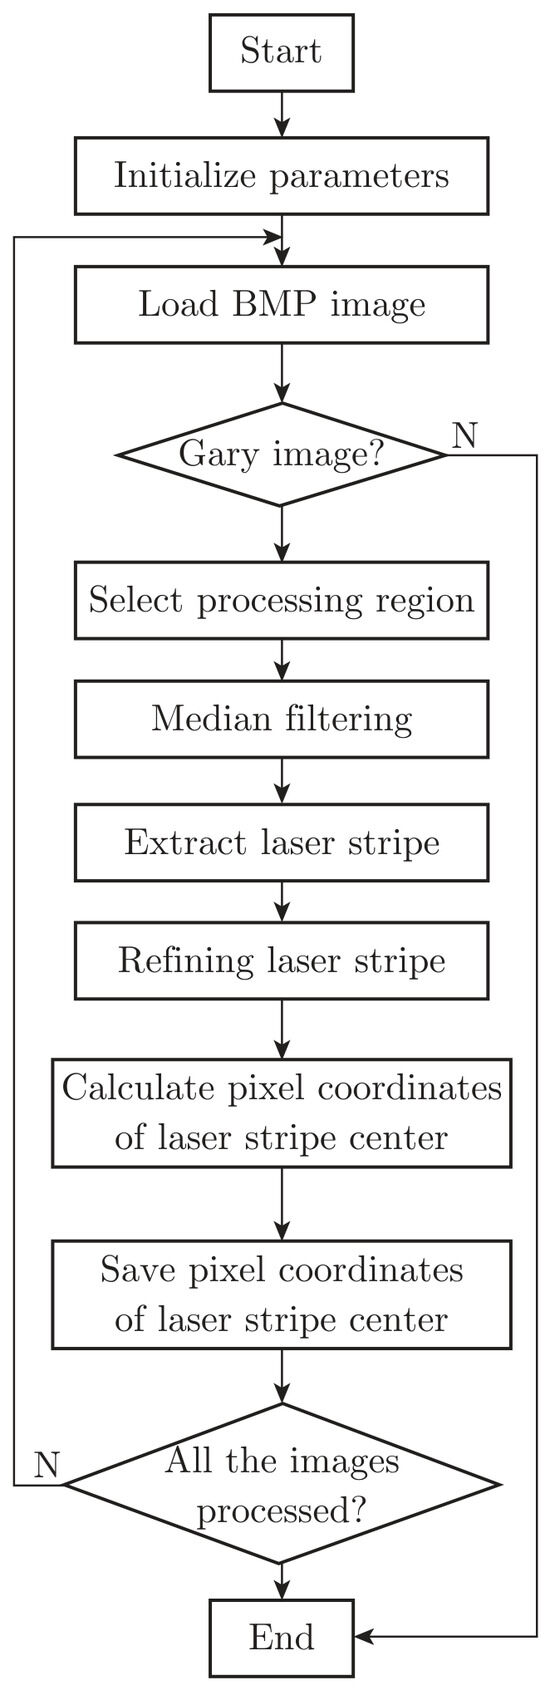
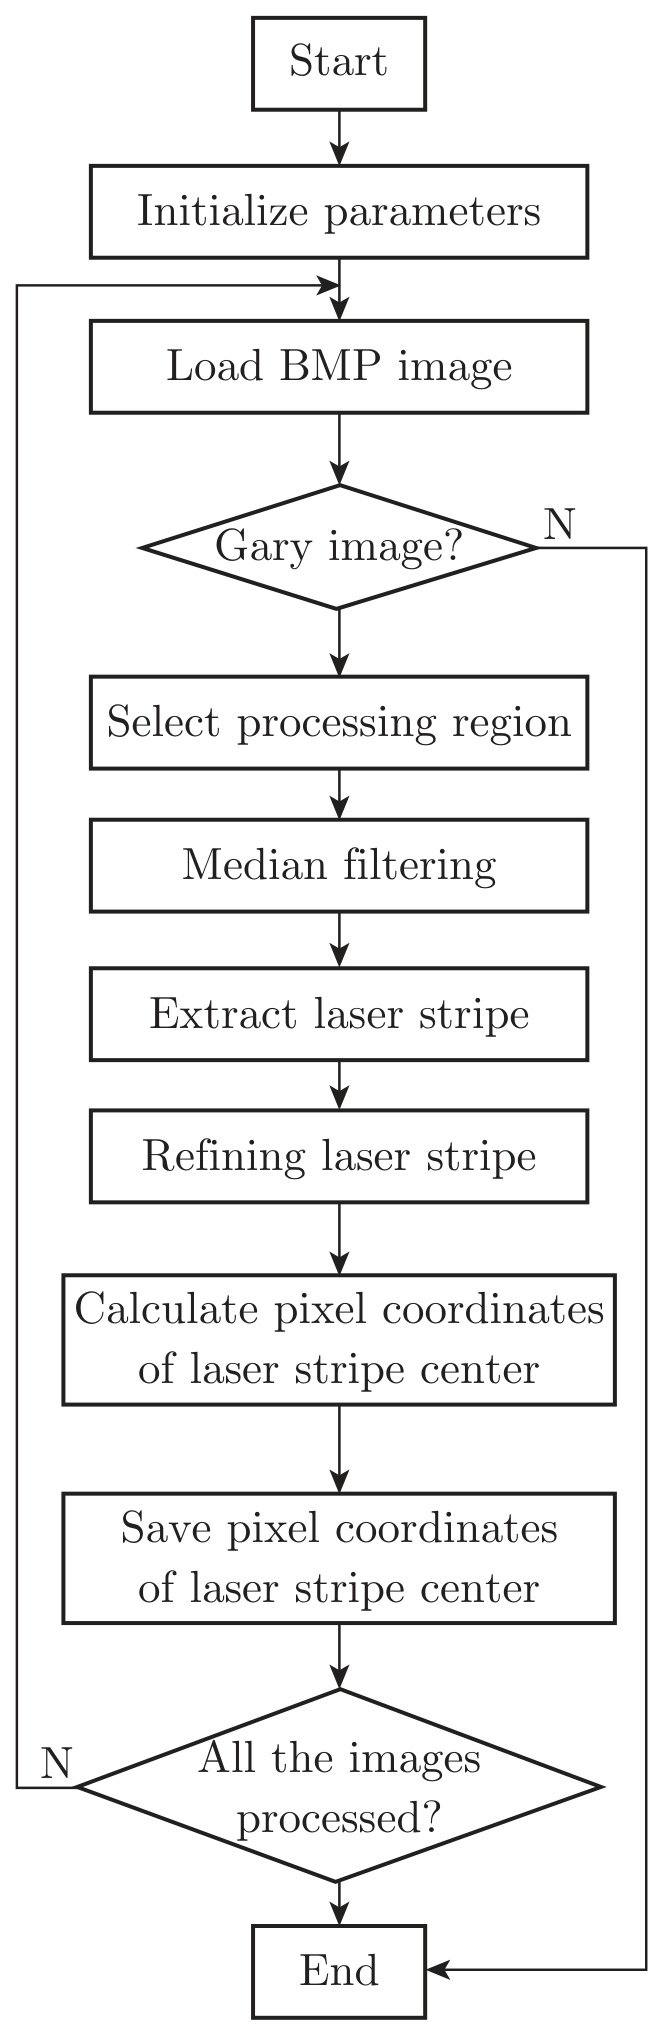
The 3D reconstruction software flow chart is shown in Figure 10.
Figure 10.
The program flow chart of image processing.
5. Conclusions
This paper combines the system with actual condition, and does some researches on the ways to get pixel coordinates of following the rotary 3D body scanning system based on structured light 3D vision measurement. The accuracy of the extraction of human body laser stripe center pixel coordinates band is a very influential factor in the system. But the discrete pixels for CCD camera are the main influence factor of gliding property of the human body laser stripes. This paper talked over and improved algorithm from these following three aspects, the main contents are shown as follows:
① Analyzing and classifying the human body laser stripe images, which are obtained from the rotary 3D human body scanning system basing on the structured light 3D vision measurement.
② Using the existing extraction algorithm of laser stripe to process the human body images is not very well, so this paper improved processing method to get center position of human body laser stripe, according to the feature of the human body images obtained from this system. From the computing result, the algorithm can process system and get all the human body laser stripe images, it proved that the algorithm applies to the system, and it could complete the calculation quickly.
③ Using the Bezier curve fitting algorithm to approximate the center line of human body scanning laser stripe, and using segmentation algorithm to discriminate different parts of the curves. The center lines of human body scanning laser stripe obtained from human body laser stripe images are fitted. The results show that this curve fitting algorithm can process all the center line of human body scanning laser stripe. It is not only keeping the original shape, but also improves the gliding property of the curves.
References
- Ye Liu, Shoushan Jiang, Xin Zhang, Body measurement point of monocular vision based on cloud data processing [J]. J. Text. 2009.03, Vol. 30(No. 3), 126–131.
- Xiaojie Li, Study on Key Technologies to Enhance the Performance of Laser 3D Body Scanning System [D], Tianjin University, 2010, 16.
- Fangfa Shu, Study on Portable Apparel Customization System Based on Monocular Vision [D], Xi’an Polytechnic University, 2008, 62.
- Long Huo, Aijun Zhang, Weijun Liu, Study on the extraction method of light knife center visual 3D measurement of structured light [J]. Comput. Appl. Softw. 2006.10, Vol. 23(No. 10), 100–102.
- Yong Ai, The New Optical Measurement Application [M], Wuhan: University of Science and Technology of Surveying and Mapping Press, 1994.
- Shiliang Xu, Numerical Analysis and Algorithm [M], Beijing: Mechanical Industry Press, 2007.
- Jin Fang, Lihong Ren, Yongsheng Ding et al., A 3D body measurement method with a single camera [J]. J. DongHua Univ. (Natural Science) 2010, 36(5), 536–540.
- Dandan Chen, Demin Yu, Zengbu Xu et al., Research on three views of 3D measurement on human body with line laser of vision calibration system [J]. Comput. Meas. Control 2008, 16(9), 1249–1251.
- Yuan Yuan, Basing on Camera Self Calibration Technique of Non-contact Body Measurement [D], Da Lian Light Industry Institute, 2005, 1-2.
- Zhou Zhu, Research and Virtual Trying on Technology to Get the 3D Information of Human Body [D], Hua Zhong University of Science and Technology, 2004, 12-13.
- Long Wu, Basing on Three Dimensional Body Measurement Parameter Mannequin [D], Shaanxi: Xi’an Polytechnic University, 2006, 9-11.
- Jingmiao Zhao, The Non-contact Body Measurement System of Digital Image Processing andMeasurement of Human Information Acquisition [D], Tian Jin University of Technology, 2004, 1-3.
- Lei Xia, Three dimensional body measurement technology in apparel industry [J]. Shanghai Text. Sci. Technol. 2006, 34(5), 76–77.
- Yongwen Yu, Three-dimensional body measurement and fitting garment cutting [J]. J. Text. 1996, (6), 29–31.
- Deqiang He, Research on Automatic Measuring System for 3D Human Body Size [D], Jiao Zuo Institute of Technology, 4, 2001, 3.
© 2015 Textile Bioengineering and Informatics Society. This article is an open access article distributed under the terms and conditions of the Creative Commons Attribution (CC BY) license (https://creativecommons.org/licenses/by/4.0/).