Skip to Content
You are currently on the new version of our website. Access the old version .
  • 4.8
    Impact Factor
  • 11.3
    CiteScore
  • 25 days
    Submission to First Decision
  • 4 days
    Acceptance to Publication

Journal of Sensor and Actuator Networks

Journal of Sensor and Actuator Networks is an international, peer-reviewed, open access journal on the science and technology of sensor and actuator networks, published bimonthly online by MDPI.  

Get Alerted

Add your email address to receive forthcoming issues of this journal.

All Articles (838)

  • Article
  • Open Access

Calibration Identifiability and Conditional Design Choices for a Dual-FBG Displacement Sensor

  • Aidana Bazarbay,
  • Rashida Kadyrova and
  • Ardak Yeleuova
  • + 5 authors

This computational study examines whether a published optical calibration identifies mechanical parameters and supports a unique design recommendation for a dual fiber Bragg grating (FBG) cantilever–spring displacement sensor. Within the adopted series compliance model, the 39.47 pm/mm sensitivity identifies the product of strain transfer and equivalent stiffness. The same anchor admits K = 71.969–91.228 N/m for η = 0.80–1.00. A counterexample extracted from archived nonlinear results shows that η = 0.9500 and 0.9595, with compatible reference stiffnesses of 75.979 and 75.183 N/m, retain only Selected 2 and Selected 3, respectively, across four declared tip geometries under unchanged constraints. Thus, the calibration does not identify a robust choice among the five retained candidates within this family. Selected 2’s nominal 43.07% nonlinearity reduction costs 23.54% more force. Retrospective published optical cycles give a fixed zero root mean square error (RMSE) of 153.6 pm on 37 recovered markers; coordinate and ruler uncertainty preclude hardware accuracy claims. Existing finite element, uncertainty, thermal, bonding and wavelength allocation analyses provide supporting conditional assessments. The contribution is a sensor-specific demonstration of which mechanical and design conclusions remain underdetermined by the adopted calibration. Independent physical validation remains necessary for predictive hardware claims.

J. Sens. Actuator Netw.

11 November 2026

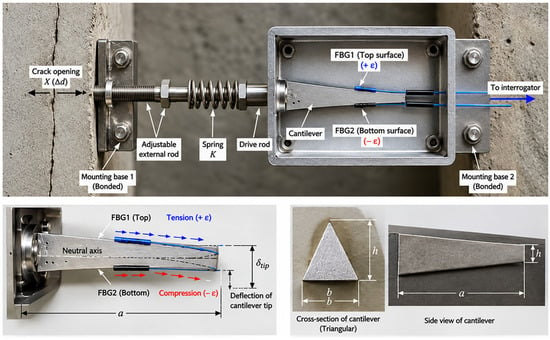
Reference dual fiber Bragg grating (FBG) cantilever–spring architecture used to define the computational benchmark configuration [13].
  • Article
  • Open Access

As an innovative application of wireless sensor networks (WSNs), the Solar Insecticidal Lamp Internet of Things (SIL-IoTs) is widely deployed for green pest control. However, existing deployment strategies commonly assume homogeneous energy-harvesting capabilities among nodes and mandate full coverage, thereby overlooking the realities of uneven solar irradiation and budget constraints in complex 3D terrains. To address these issues, this paper investigates the SIL deployment problem using real DEM data. We first introduce a 3D coverage model alongside a terrain-based solar energy weight model, and formulate the task as a partial coverage optimization problem constrained by both energy harvesting and budget limitations. To solve this problem and avoid premature convergence, we propose an Improved Jumping Particle Swarm Optimization (IJPSO) algorithm. Experimental results on benchmark datasets and DEM-based 3D terrain simulations demonstrate that IJPSO outperforms six competing algorithms, achieving average relative percentage deviations (RPD) of 0.045% and 0.140% and average 3D deployment objective values of 62.27 and 84.37 under the 80% and 90% coverage constraints, respectively. These results demonstrate the effectiveness of IJPSO in reducing deployment costs while maintaining solution consistency.

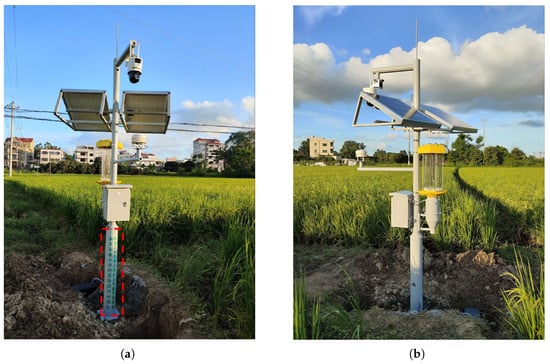
Diagram of nodes in SIL-IoTs: (a) rear view of SIL node; (b) side view of SIL node. The content in red dashed box indicates “Nanjing Agricultural University, Team of Professor Lei Shu” and “Compact Multi-Parameter Intelligent Agricultural Data Acquisition System”.
  • Article
  • Open Access

The article presents a comprehensive methodology for assessing the safety of highly automated vehicles (HAVs) based on operational data collected on public roads. The methodology includes a qualitative classification of safety violations according to three criteria: impact on functionality, extent of coverage by safety mechanisms, and frequency of occurrence. Based on the sum of these criteria, a criticality matrix is constructed, distinguishing four risk zones: critical (requiring immediate remediation), unacceptable (requiring planned remediation), tolerable, and acceptable. The quantitative assessment includes a system of key performance indicators (operational efficiency, number of accidents, detection and elimination of threats, and frequency of driver/operator interventions) and an integral safety indicator. The applicability of the methodology was demonstrated using operational data from a Level 3 HAV collected over 1413 km of automated driving on Russian highways. In this demonstration, most of the recorded failures were classified in the critical zone, which made it possible to prioritize system improvements. The proposed methodology can be used by developers for the objective assessment of safety and by regulators for developing reporting requirements. From the perspective of sensor and actuator networks, this work makes three contributions: (1) the multimodal sensor network of the HAV (4 cameras, 4 radars, GNSS RTK) is analyzed as a networked system with redundancy and overlapping fields of view; (2) the CAN bus is treated as an actuator network whose reliability is critical for safety; (3) it is shown that 10 of 17 recorded failures (59%) are related specifically to network equipment, making the monitoring of sensor and actuator networks a central element of the proposed methodology.

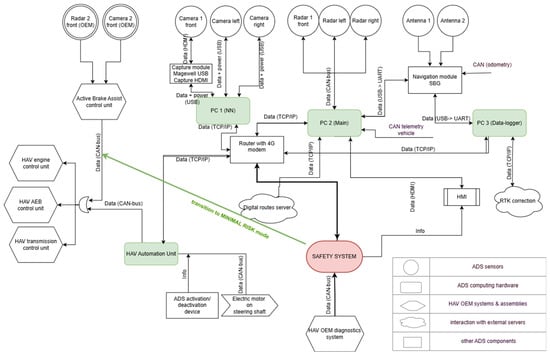
Architectural diagram of the developed ADS.
  • Article
  • Open Access

The rapid growth of the Internet of Things (IoT) in safety–critical applications requires lightweight and robust security mechanisms for resource–constrained devices. Existing authentication and key agreement schemes, including that of Al-Hejri et al., suffer from critical weaknesses, such as state desynchronization, lack of sender-forward secrecy, non–atomic authenticated encryption, replay and device cloning vulnerabilities, and insufficient formal verification. This paper introduces FRACE–IoT, a lightweight, hardware–bound forward–secure, and cloning–resistant authenticated encryption scheme for heterogeneous four–tier IoT networks. The proposed approach combines Curve25519 cryptography, physical unclonable functions, authenticated ChaCha20–Poly1305 encryption, and HKDF–BLAKE3 key derivation within a single–pass key establishment architecture that achieves sender-forward secrecy and hardware-enforced protection against credential extraction. Security analysis and formal verification using the BAN logic and the AVISPA tool under the Dolev–Yao model confirm session key security, mutual belief, and robust resistance to major cyber-attacks. Experimental evaluation on real embedded hardware IoT boards, namely, FIT IoT–LAB M3 and Nordic nRF52840DK, demonstrates that FRACE–IoT achieves a reduced computation cost of 187.92 ms, communication overhead of 1344 bits, and a total energy consumption of 210.10 mJ, making it suitable for efficient and scalable IoT security deployment.

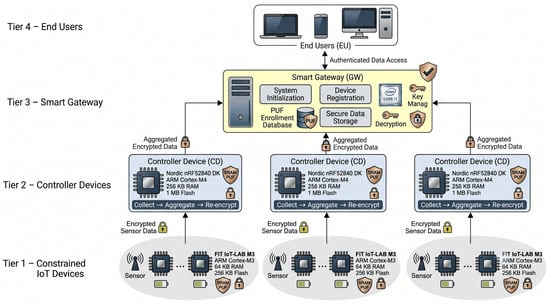
FRACE-IoT heterogeneous four-tier IoT network model.

Featured Articles of Last Quarter

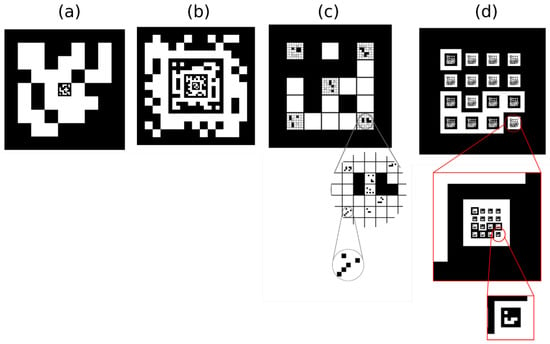
Visual comparison of multi-scale markers: (a) Embedded ArUco [13]. (b) Fractal marker [14], (c) Harco marker [16]. (d) Our proposed Recursive ArUco marker (RArUco).

Highly Accessed Articles

News & Conferences

Latest Issues

Open for Submission

Journal Sections

XFacebookLinkedIn
J. Sens. Actuator Netw. - ISSN 2224-2708