


Abstract
The low efficiency of photovoltaic (PV) systems arises from their nonlinear current-voltage characteristics, necessitating the use of maximum power point tracking (MPPT) techniques. Conventional MPPT methods are popular for their simplicity and low cost but exhibit poor performance under rapidly changing atmospheric conditions, leading to considerable energy losses. Under uniform solar irradiation, these traditional approaches can locate the maximum power Point (MPP), yet their reliance on small, fixed step sizes causes oscillations and output ripple. In dynamic environmental conditions, they often fail to accurately track the true MPP. To address these challenges, this paper proposes an MPPT strategy based on the artificial Gorilla Troops Optimizer (GTO) to enhance PV performance under partial shading conditions (PSCs) and fast climatic variations. An enhanced version of the algorithm (EnGTO) was developed to further improve MPPT efficiency. Comparative simulations with the perturb and observe (P&O) method and the classic GTO demonstrate that the proposed approach achieves rapid response to environmental changes and higher accuracy and lower oscillations under PSCs, reaching efficiencies of up to 99.96% (STCs) and 99.81% (PSCs).
1. Introduction
1.1. Background and Motivation
The growing public awareness of environmental issues has led to the adoption of renewable energy sources as an alternative to fossil fuels. Since 2015, the year the Paris Agreement was adopted, global investment in renewable and nuclear sources has exceeded that in fossil fuels, as pointed out by the International Energy Agency (IEA). Among these renewable energy sources, solar energy has emerged due to its growing relevance in the global energy scenario, with optimistic projections indicating continued growth in the sector until at least 2032 [1,2].
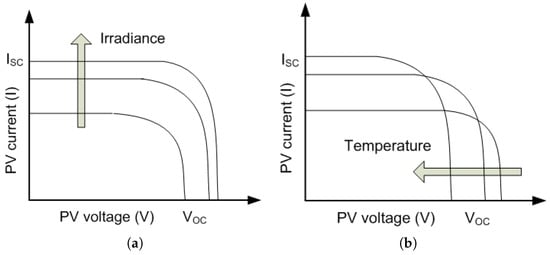
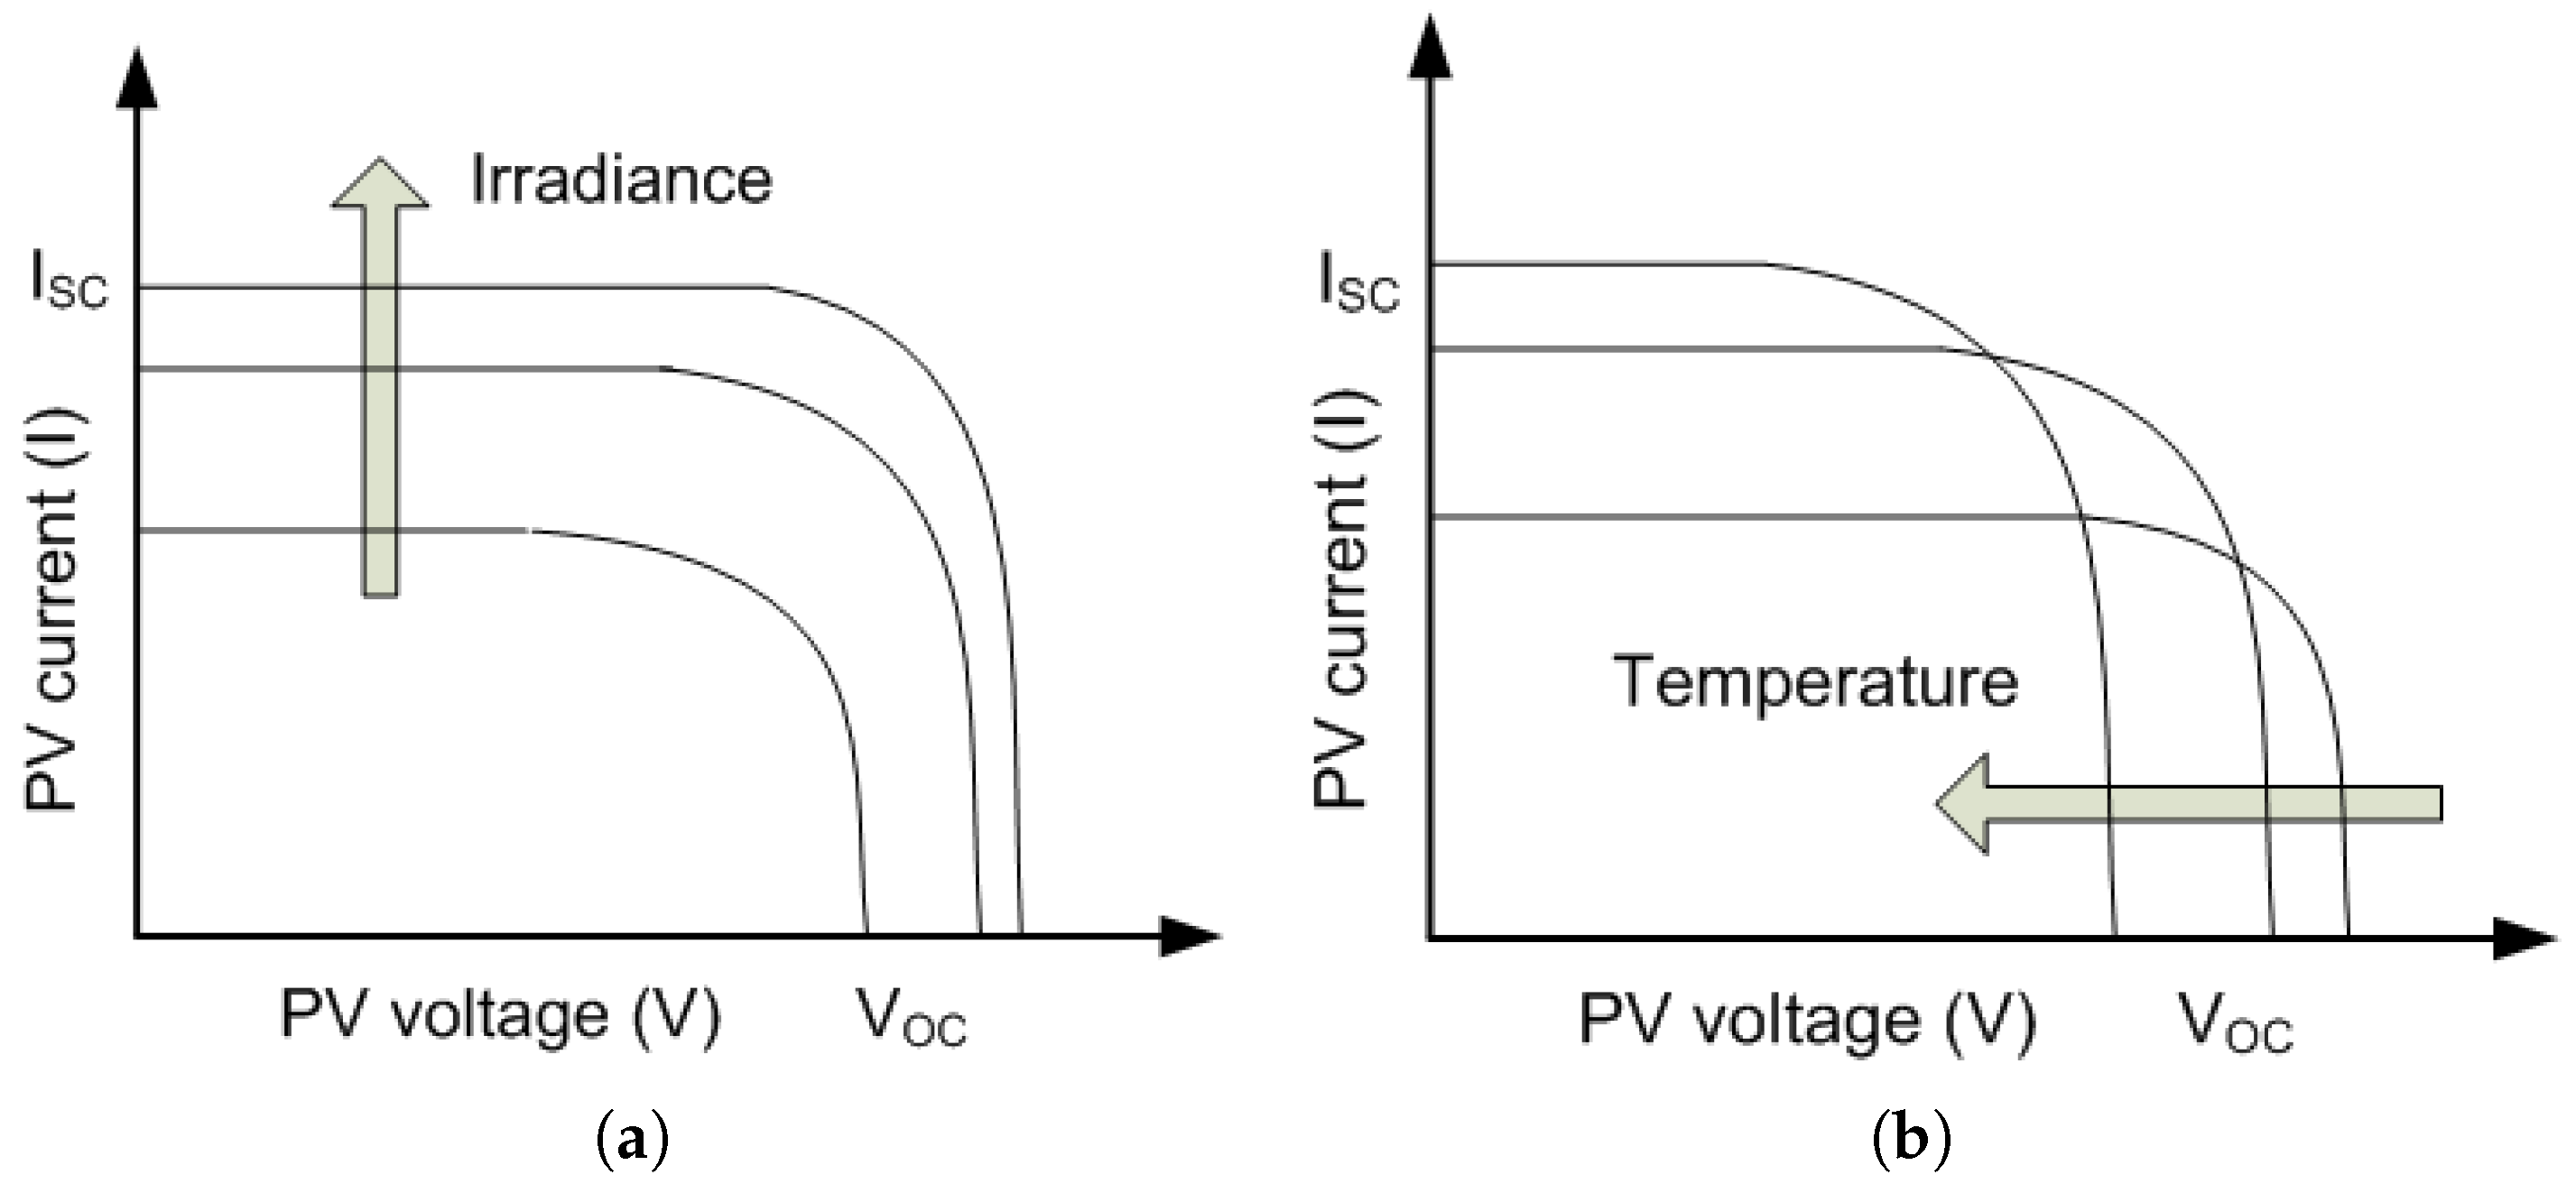
Photovoltaic cells are the central elements in the conversion of solar radiation to electrical energy, mainly using semiconductor materials such as silicon. When light strikes these cells, photons transfer enough energy to release electrons from the semiconductor material, creating an electric current. To increase the available power, several cells are interconnected to form photovoltaic (PV) modules, in which series and parallel connections allow higher voltage and current levels to be achieved. The photovoltaic cell has a nonlinear relationship between the current and voltage, described by its characteristic I-V curve. This curve is directly influenced by both solar irradiance (Figure 1a) and temperature (Figure 1b). As the temperature increases, there is a reduction in the open-circuit voltage () and a slight increase in the short-circuit current (). The increase in temperature is associated with a decrease in efficiency, resulting in lower power generation. The open-circuit voltage increases logarithmically with increasing irradiance, while the short-circuit current increases linearly with irradiance, which results in an increase in power generation, provided that the temperature conditions are favorable [3].
Figure 1.
Influence of irradiance and temperature on the I-V characteristic curve of the photovoltaic cell: (a) effect of irradiance and (b) effect of temperature.
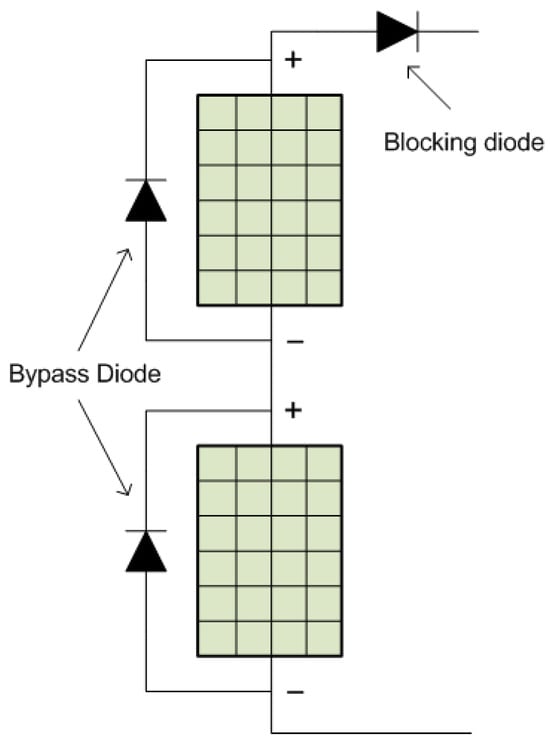
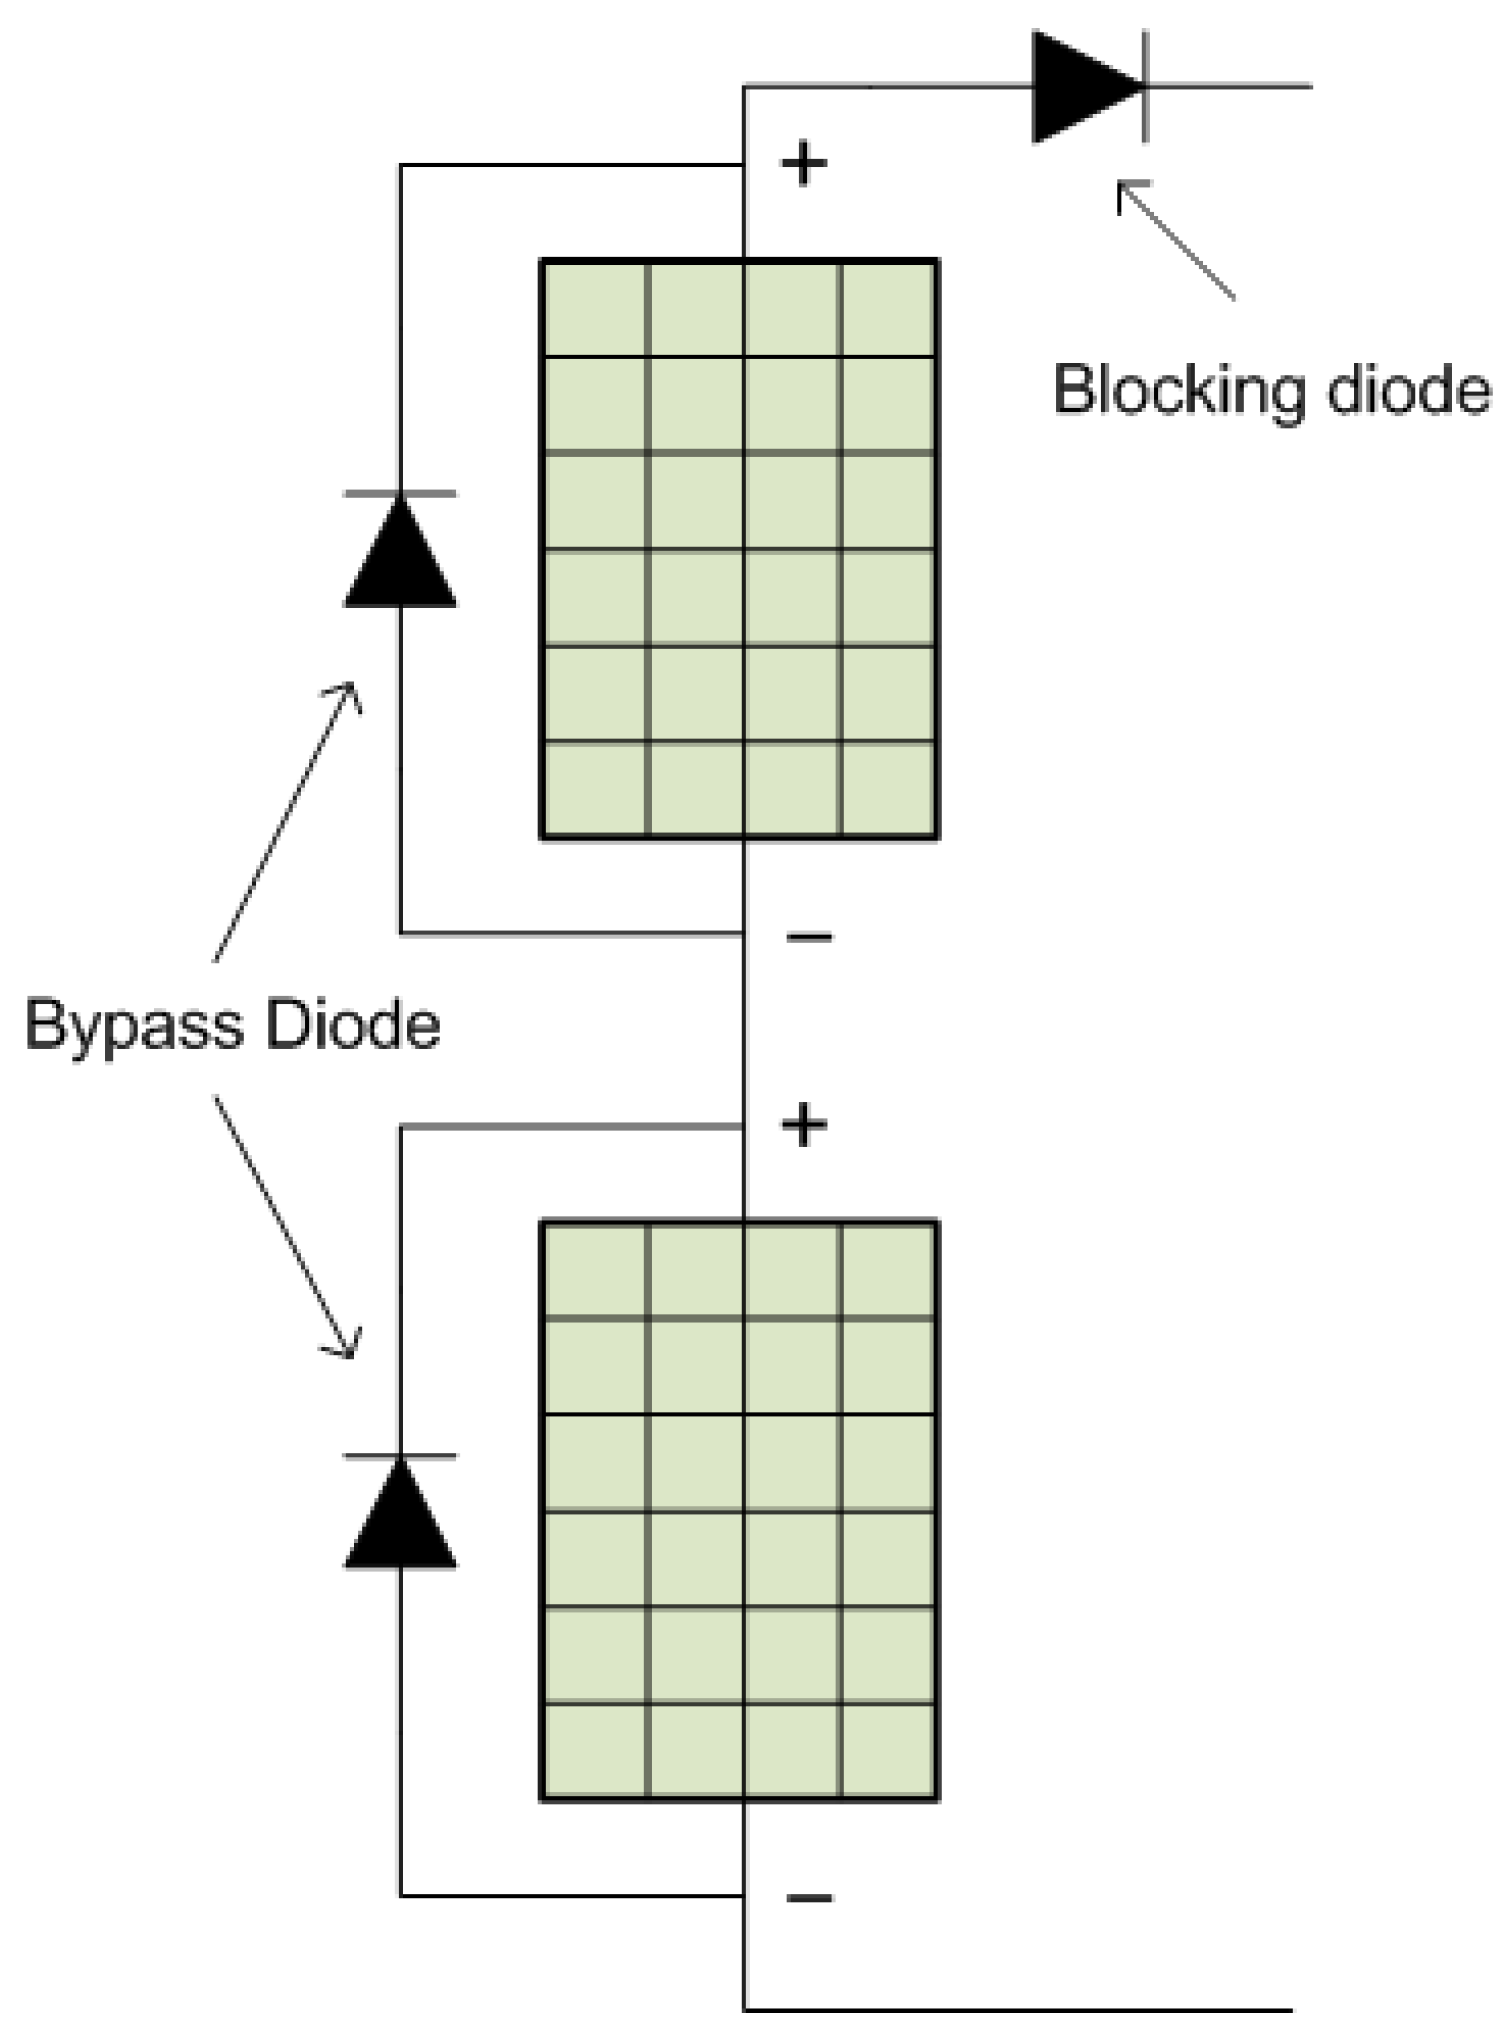
In a series connection of photovoltaic cells, the overall performance of the module can be compromised if one of the cells has lower efficiency, a common situation in cases of partial shading. In such cases, the current of the entire assembly is limited by the cell with the lowest capacity. To mitigate this problem, bypass diodes are used, as illustrated in Figure 2.
Figure 2.
Bypass diodes and blocking diodes in series-connected modules.
These components create an alternative path for the electric current, allowing the affected cell to be bypassed. This not only prevents the module’s production from being restricted but also reduces heat dissipation in that same cell, since the reverse biased voltage could cause the creation of a hotspot [4]. Although, in theory, it would be advisable to associate a bypass diode with each individual cell, the usual practice is to connect a diode to groups of cells for economic reasons. Blocking diodes, on the other hand, have the function of preventing current from flowing in the opposite direction of that intended [5].
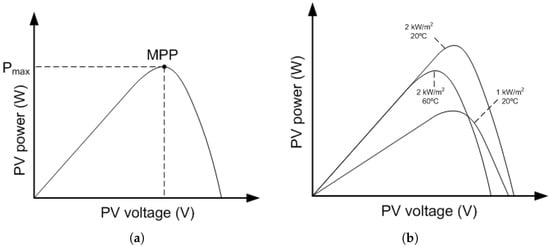
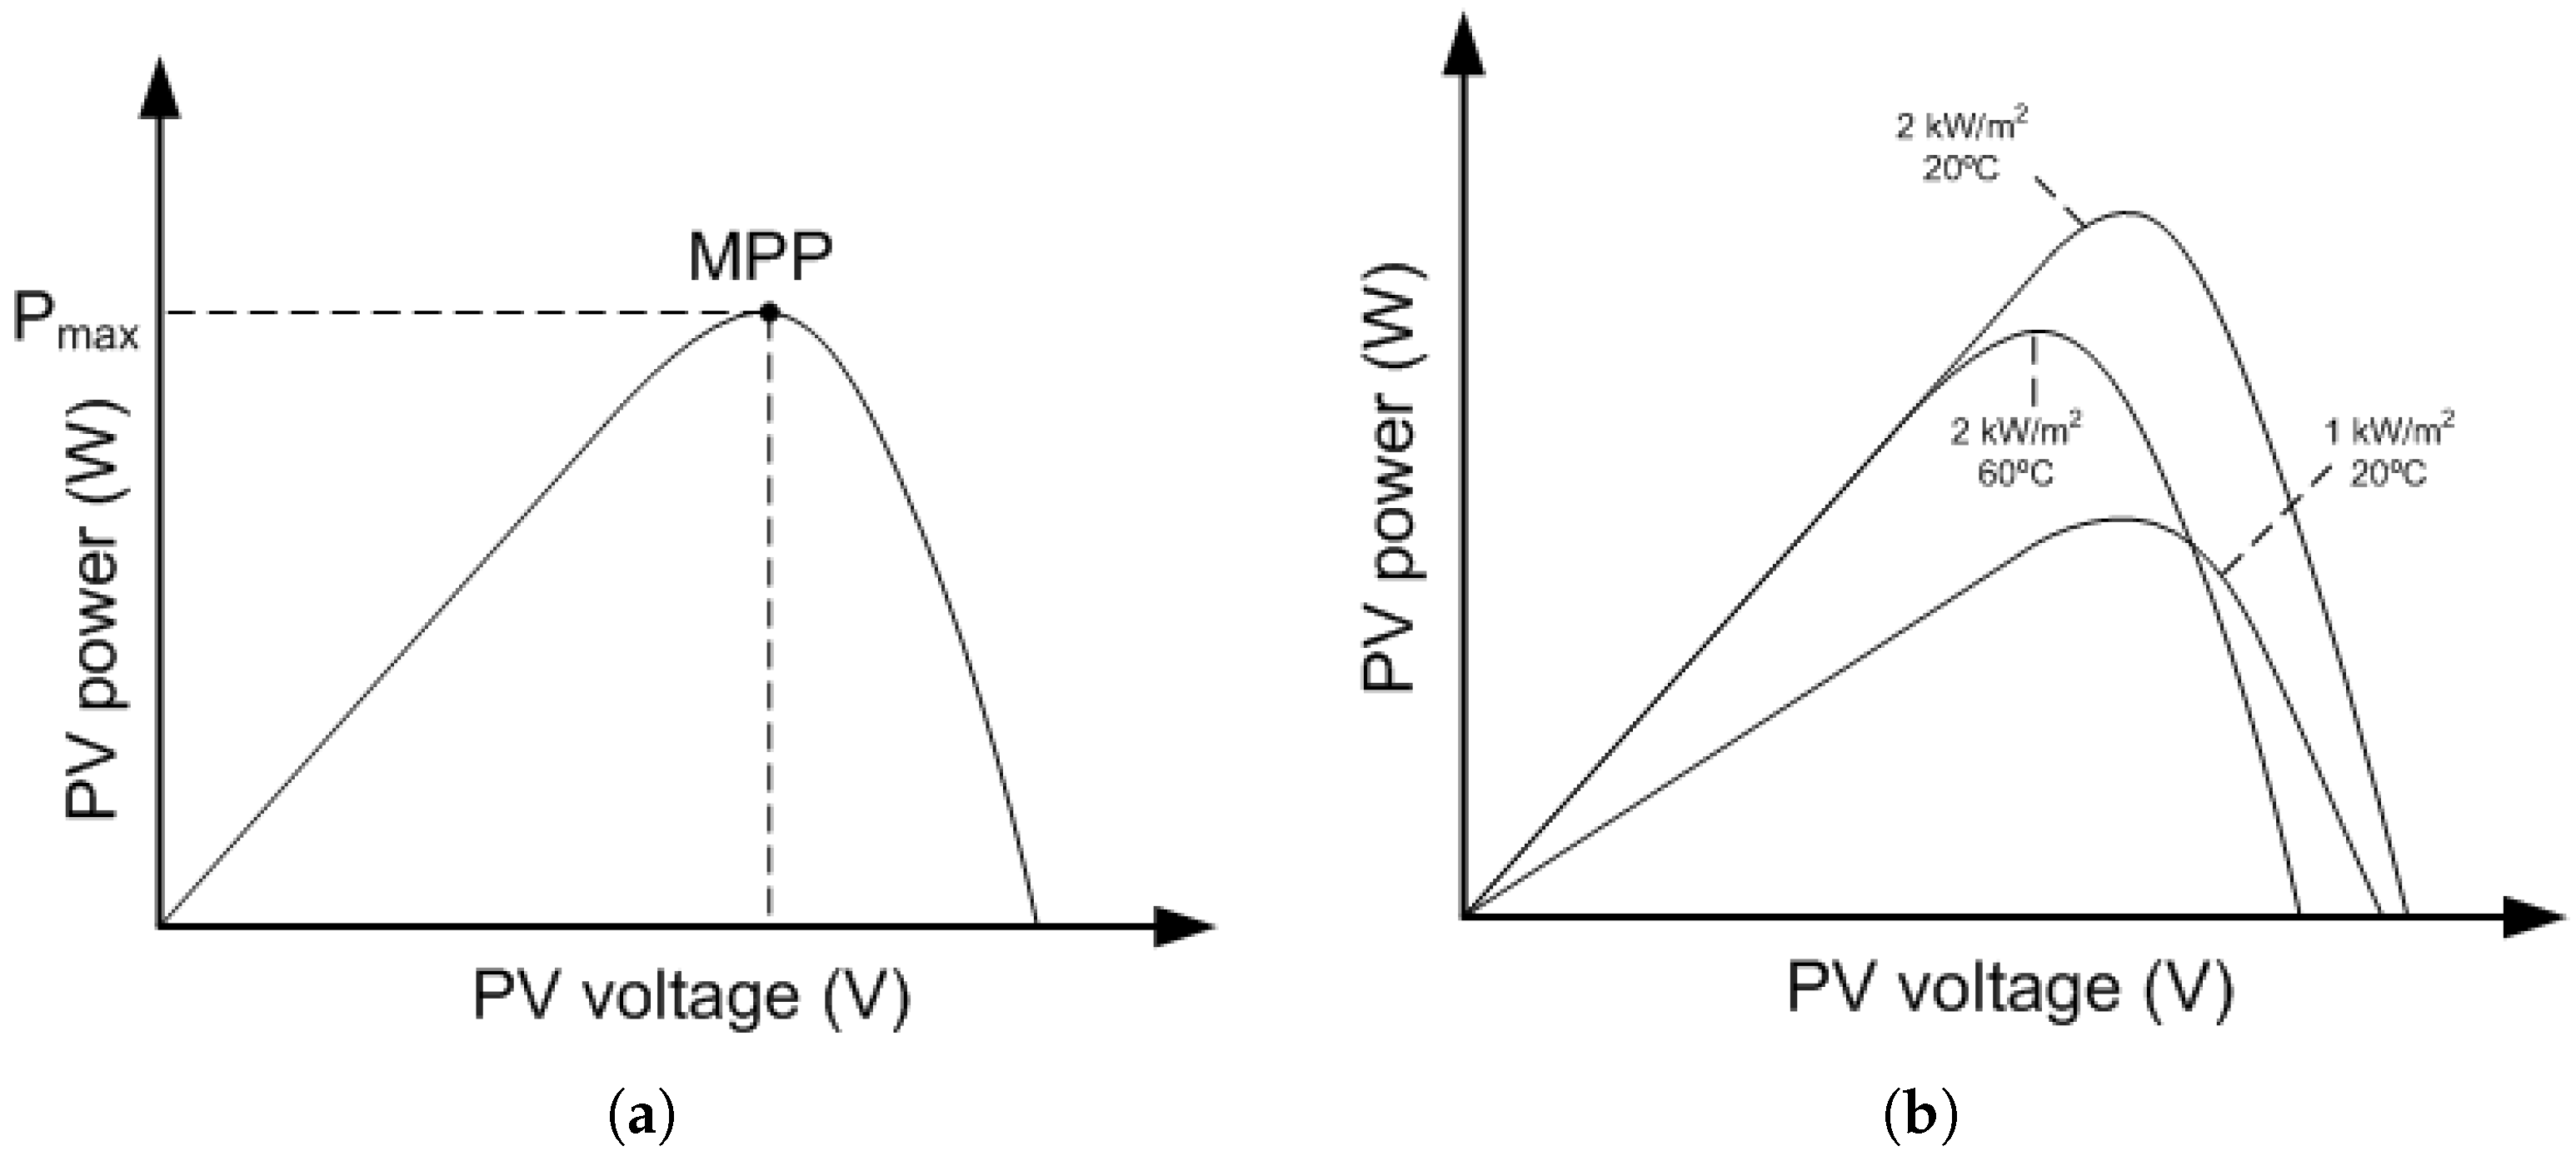
Figure 3a shows the power-voltage (P-V) curve of a photovoltaic module, highlighting the maximum power point (MPP), which indicates the highest power that the module can supply under current conditions. Since power is the result of multiplying the current by the voltage, the P-V curve is influenced by factors such as temperature and irradiance, as shown in Figure 3b. In other words, a rapid change in environmental conditions alters the MPP. To deal with these variations and extract as much energy as possible from the module, maximum power point tracking (MPPT) techniques are used, which help to maintain the efficiency of the photovoltaic system even under variable conditions [2,3,6].
Figure 3.
(a) P-V characteristic curve. (b) Variation in the P-V curve in relation to temperature and irradiance.
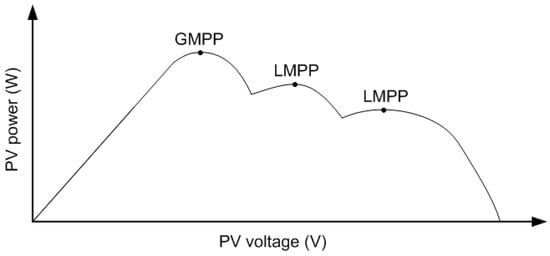
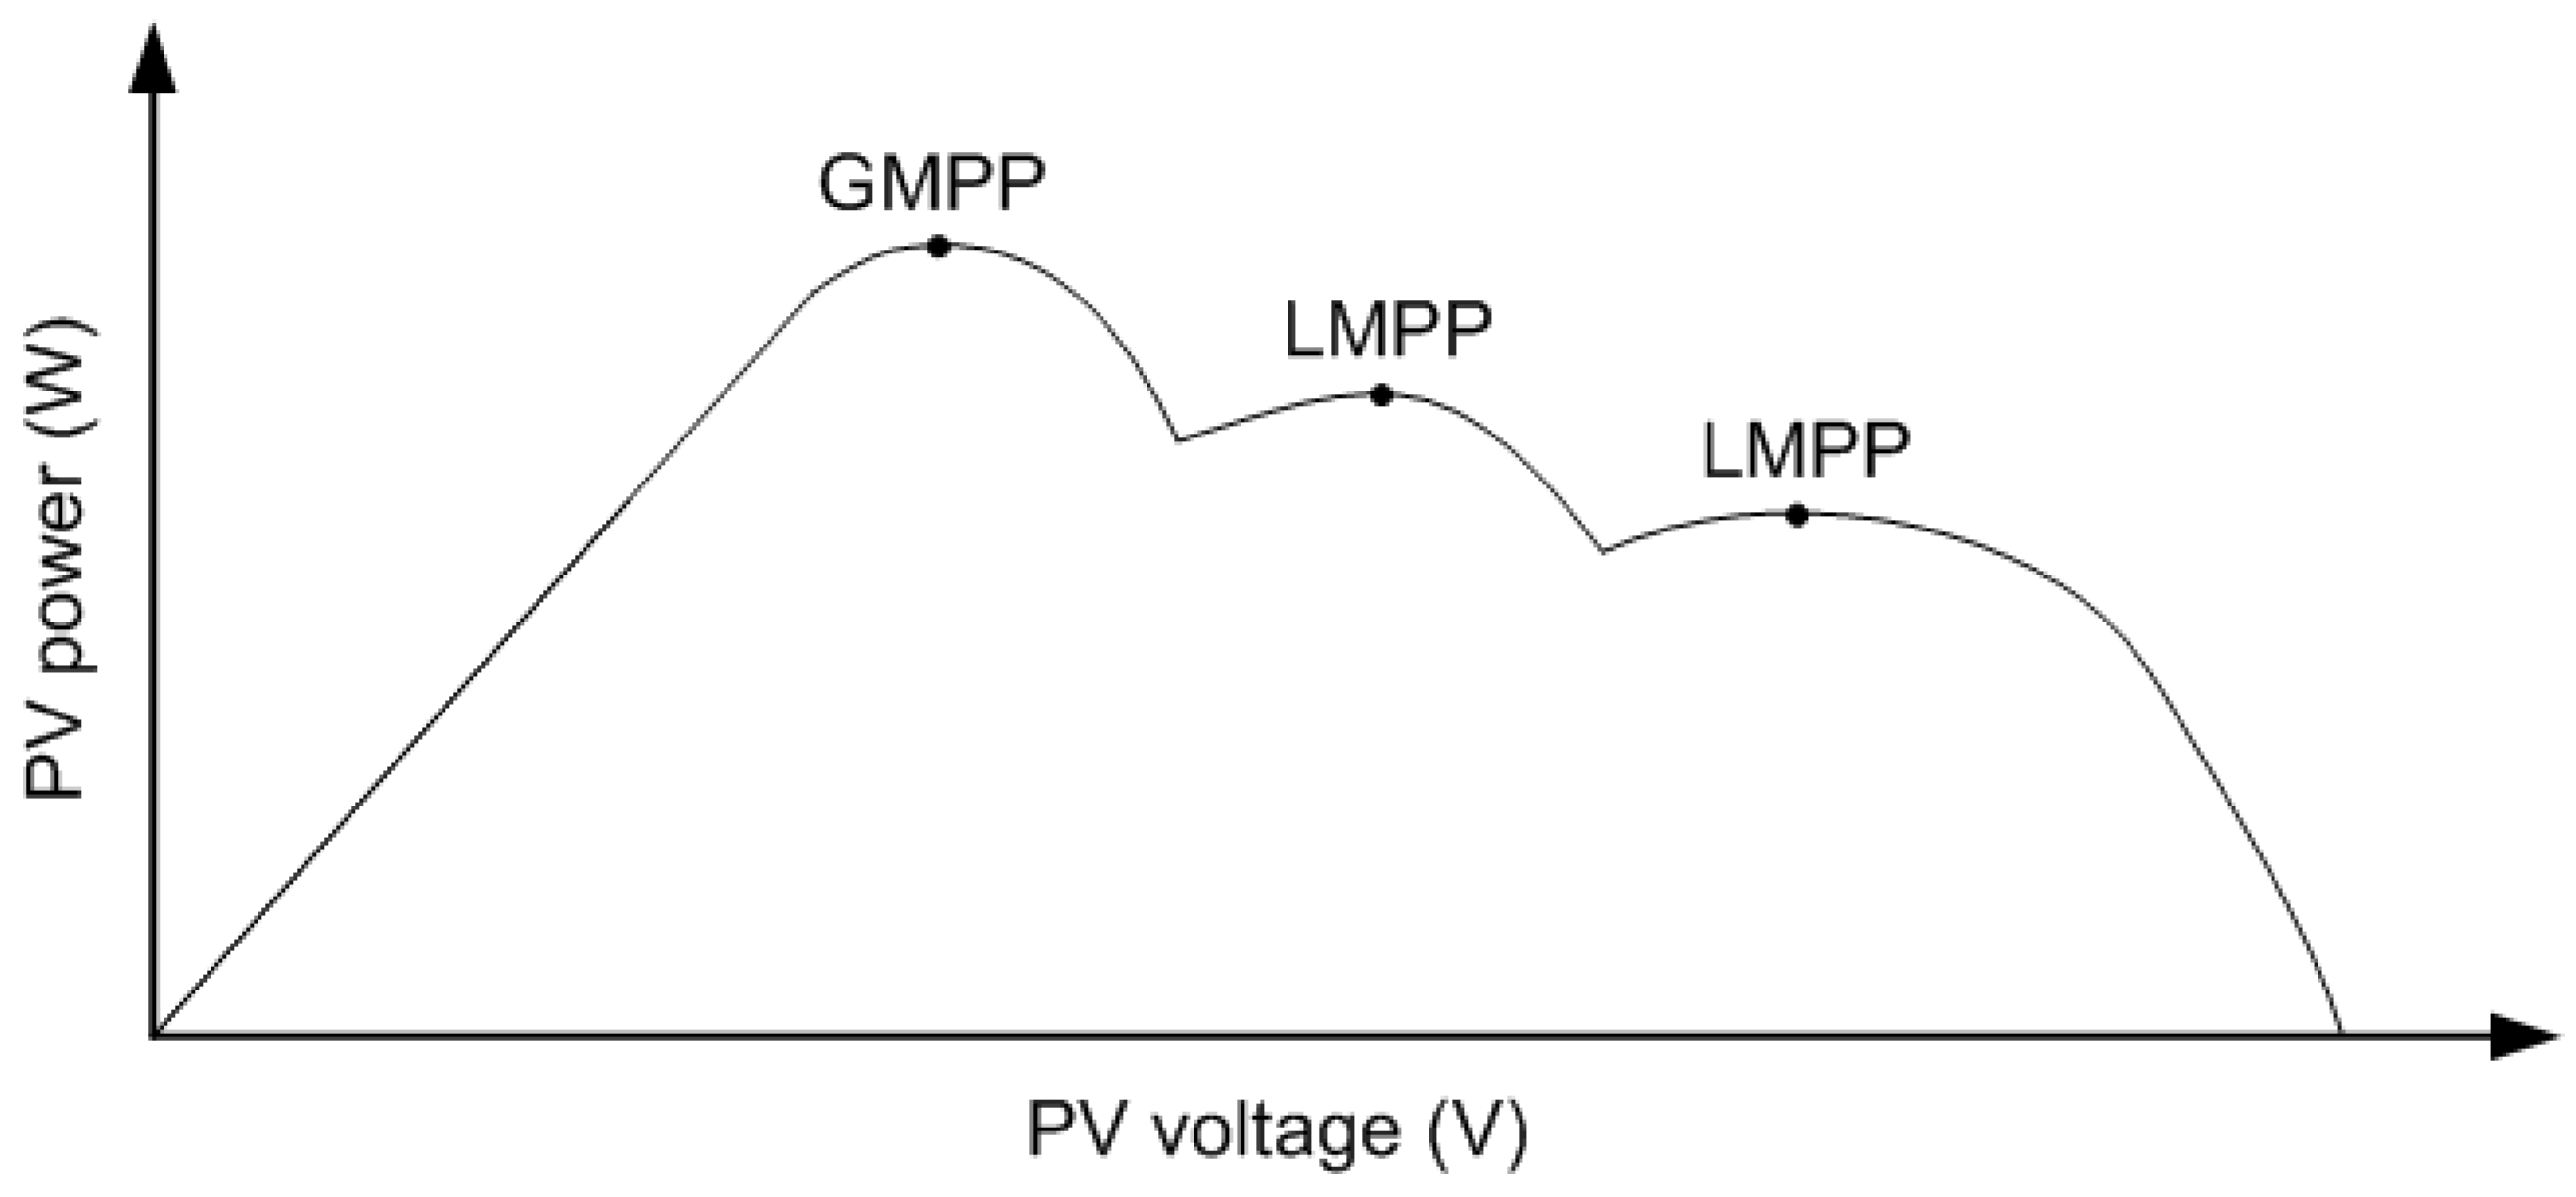
A significant challenge arises in partial shading conditions (PSC), where the PV is partially covered, for example, by a cloud. Unlike the P-V curve shown in Figure 3a, which reflects uniform temperature and irradiance conditions, in these scenarios, the P-V characteristic exhibits multiple power peaks, as evidenced in Figure 4. These peaks correspond to several local maximum power points (LMPPs), while only one of them represents the global maximum power point (GMPP), which is the result of the bypass diodes. Conventional MPPT algorithms often fail to differentiate between the local maximum and global maximum, thus causing significant energy losses. Several advanced strategies have been proposed to overcome this limitation and will be discussed, together with traditional techniques, in subsequent sections of this paper [7,8,9].
Figure 4.
P-V characteristic curve under PSCs.
1.2. Evolution of MPPT Approaches
MPPT techniques are generally classified in the literature into four categories: classic, intelligent, optimization-based and hybrid. Classic techniques stand out for their simplicity and low implementation cost, but they have limited efficiency in conditions of rapid environmental changes and under PSCs. Intelligent techniques, based on fuzzy logic or artificial neural networks, are highly adaptable and perform well in MPP tracking, although they have limitations in PSCs and are associated with high control complexity. Optimization techniques, based on behavior observed in the animal kingdom, are associated with a high capacity for GMPP tracking even under PSCs. However, their efficiency depends directly on the appropriate choice of initial parameters. Finally, hybrid techniques represent evolution, combining different techniques with the aim of increasing system efficiency [7,8].
Historically, the industry has relied on conventional algorithms such as perturb and observe (P&O) and incremental conductance (INC). These methods are favored for their low computational cost and ease of hardware implementation. However, the literature identifies two fatal flaws in these traditional approaches. (1) Steady-State Oscillations: Conventional methods rely on a fixed step size. A large step size enables faster tracking but causes the power output to oscillate around the peak, whereas a small step size reduces oscillations but fails to respond to rapid weather changes. (2) Partial Shading Conditions (PSCs): When a portion of the PV array is shaded by clouds, trees or nearby buildings, the P-V curve becomes multi-modal, featuring multiple local maximum power points (LMPPs) and one global maximum power point (GMPP). Traditional algorithms like P&O lack the ability required to distinguish between these peaks and frequently become trapped at an LMPP, resulting in power losses exceeding 30–50%. To address this, the research community has shifted toward soft computing and metaheuristic algorithms, which treat MPPT as an optimization problem capable of searching the entire operating range for the GMPP [4,10,11].
The artificial Gorilla Troops Optimizer (GTO), introduced by Abdollahzadeh et al. in 2021 [12], is a state-of-the-art swarm intelligence algorithm inspired by the social behavior of gorillas. It mimics their collective life, including migration to unknown areas, following a “Silverback” leader and competition for resources [13]. The GTO has gained prominence due to its unique balance between exploration (searching for new peaks) and exploitation (refining the search near a suspected peak). Recent studies have successfully applied the GTO to complex power system problems, such as stochastic unit commitment and the integration of renewable sources into microgrids [14], optimal control parameter tuning of power system stabilizers [15], optimal power flow issue to minimize fuel costs, emissions and power losses and improving the voltage stability related to electric power networks [16], in addition to a GTO-based tracker for thermoelectric generators [17] and identification of the optimal tilt angle for photovoltaic panels [18]. Compared with older metaheuristics like particle swarm optimization (PSO) or the Grey Wolf Optimizer (GWO), the GTO offers the following [19]. (1) Faster Convergence: Its mathematical formulation allows for rapid jumps across the search space, which is critical for PV systems under fast irradiance fluctuations. (2) High Robustness: It performs exceptionally well in high-dimensional and nonlinear problems, making it suitable for complex PV array configurations. (3) Minimal Tuning: Unlike many methods in the “intelligent” category (e.g., ANN or fuzzy logic) which require extensive training or expert knowledge to build rule bases, the GTO belongs to the “optimization-based” category, offering a more streamlined implementation with fewer control parameters.
Recent research has shown that while the standard GTO is powerful, it can occasionally suffer from population stagnation in extremely complex shading scenarios. Researchers have begun developing variants to improve search efficiency, such as the following:
- The Labor Division GTO (LDGTO) [13]: Here, a variant of the GTO based on the division of labor is developed. The framework consists of two primary stages: a labor division stage, which utilizes a stimulus-response model to adaptively balance exploration and exploitation, and an outcome allocation stage, where specific search equations are assigned to ordinary and elite individuals to optimize targeted functions.
- The Novel Enhanced Version of GTO (NEGTO) [20]: A modified GTO is introduced that enhances both exploration and exploitation. By implementing a new dynamic control parameter and refined algorithmic equations, the proposed version significantly improves search efficiency.
- The Modified Gorilla Groups Optimizer (mGTO) [21]: This is an enhanced metaheuristic algorithm that integrates elite opposition-based learning (EOBL), the Cauchy inverse cumulative distribution (CICD) operator, and the tangent flight operator (TFO) into the original GTO framework to achieve a more stable balance between exploration and exploitation.
- The Enhanced Gorilla Troops Optimizer (EGTO) [22]: This is an advanced metaheuristic algorithm that improves the standard GTO by integrating the marine predators algorithm’s (MPA) high- and low-velocity ratio strategies to better balance exploration and exploitation. At the high-velocity ratio stage, the large step sizes generated during this phase represent a high level of exploratory ability, allowing search agents to cover the target space extensively to identify promising regions. At the low-velocity ratio stage, a Lévy process is used to refine the precision of the optimal solution and increase the chances of escaping local minima.
Furthermore, GTO hybrid algorithms have also been proposed, such as the Memory-Based Improved Gorilla Troops Optimizer (MIGTO) for the parameter extraction of the PV model [23], Cuckoo Search-Gorilla Troop Optimization (CS-GTO) for parameter estimation in photovoltaic modules [24], the GTO and fractional-order proportional integral derivative (FOPID) for PV MPPT [19] and the arithmetic optimization algorithm and GTO (AOA-GTO) algorithm for micro-robotics systems [25].
To the best of the authors’ knowledge, this work represents the first application of the enhanced GTO (EnGTO) algorithm to the field of PV MPPT. Unlike the existing GTO variants mentioned (which have been primarily evaluated using standard benchmark functions), the proposed EnGTO is specifically tailored and improved to address the practical complexities of MPPT. This refinement explicitly accounts for the presence of a DC/DC converter and its inherent switching dynamics. Consequently, the primary contribution of this paper lies in bridging the gap between theoretical optimization and practical power electronics by introducing a specialized control framework that ensures robust tracking performance under realistic operating conditions. The enhanced GTO (EnGTO) proposed in this paper builds on these foundations and is specifically tailored to PV MPPT. Unlike the existing GTO variants mentioned, where changes have been introduced in the exploration and exploitation phases, the proposed EnGTO prioritizes the elimination of steady-state ripples and an increase in the response speed to step changes in irradiance, The primary EnGTO innovation lies in the transition from stochastic initialization to a uniform sequential distribution restricted to 0.05 < D < 0.95, which ensures comprehensive coverage of the P-V curve from the first iteration. Crucially, the algorithm implements a sequential reorganization strategy (descending after exploration and ascending after exploitation) to harmonize the search process with the physical constraints of the power converter. This eliminates the inconvenience of erratic duty cycle jumps, allowing the system to reach a steady state much faster. These structural refinements result in highly significant reductions in convergence times together with enhanced stability at the operating point while maintaining a good tracking efficiency that reaches 99.96%. This represents the current technological ceiling for PV control, outperforming the benchmarks set by earlier approaches applied specifically to PV MPPT.
The remainder of this paper is organized as follows. Section 2 provides a detailed technical description of the conventional perturb and observe (P&O) and the metaheuristic artificial Gorilla Troops Optimizer (GTO) algorithms. Section 3 outlines the simulation environment and parameters, including the solar panel modeling, DC/DC converter design and presentation of the proposed enhanced artificial Gorilla Troops Optimizer (EnGTO). This section also presents and discusses the simulation results, offering a comparative performance analysis under both static and dynamic environmental conditions. Finally, Section 4 concludes the paper by summarizing the key findings and contributions.
2. Description of the P&O and GTO Algorithms
This section describes the perturb and observe (P&O) algorithm and the artificial Gorilla Troops Optimizer (GTO). The proposed enhanced GTO (EnGTO) algorithm will be presented later, after the GTO results have been analyzed.
2.1. Perturb and Observe (P&O)
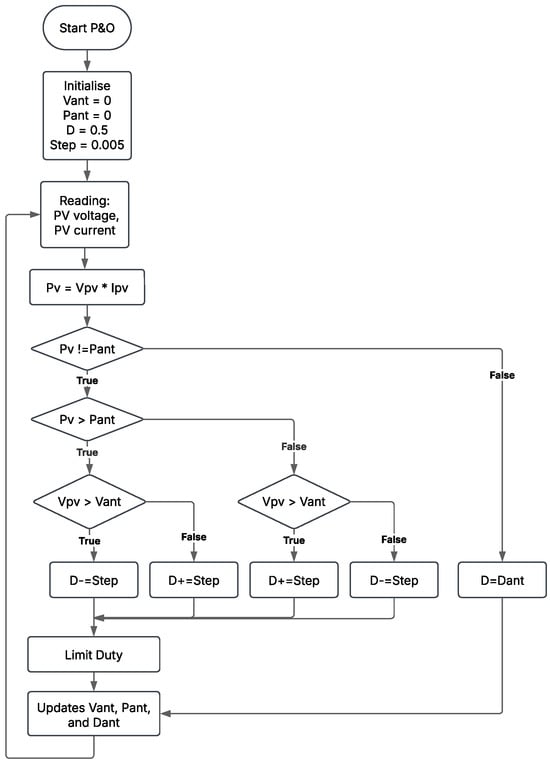
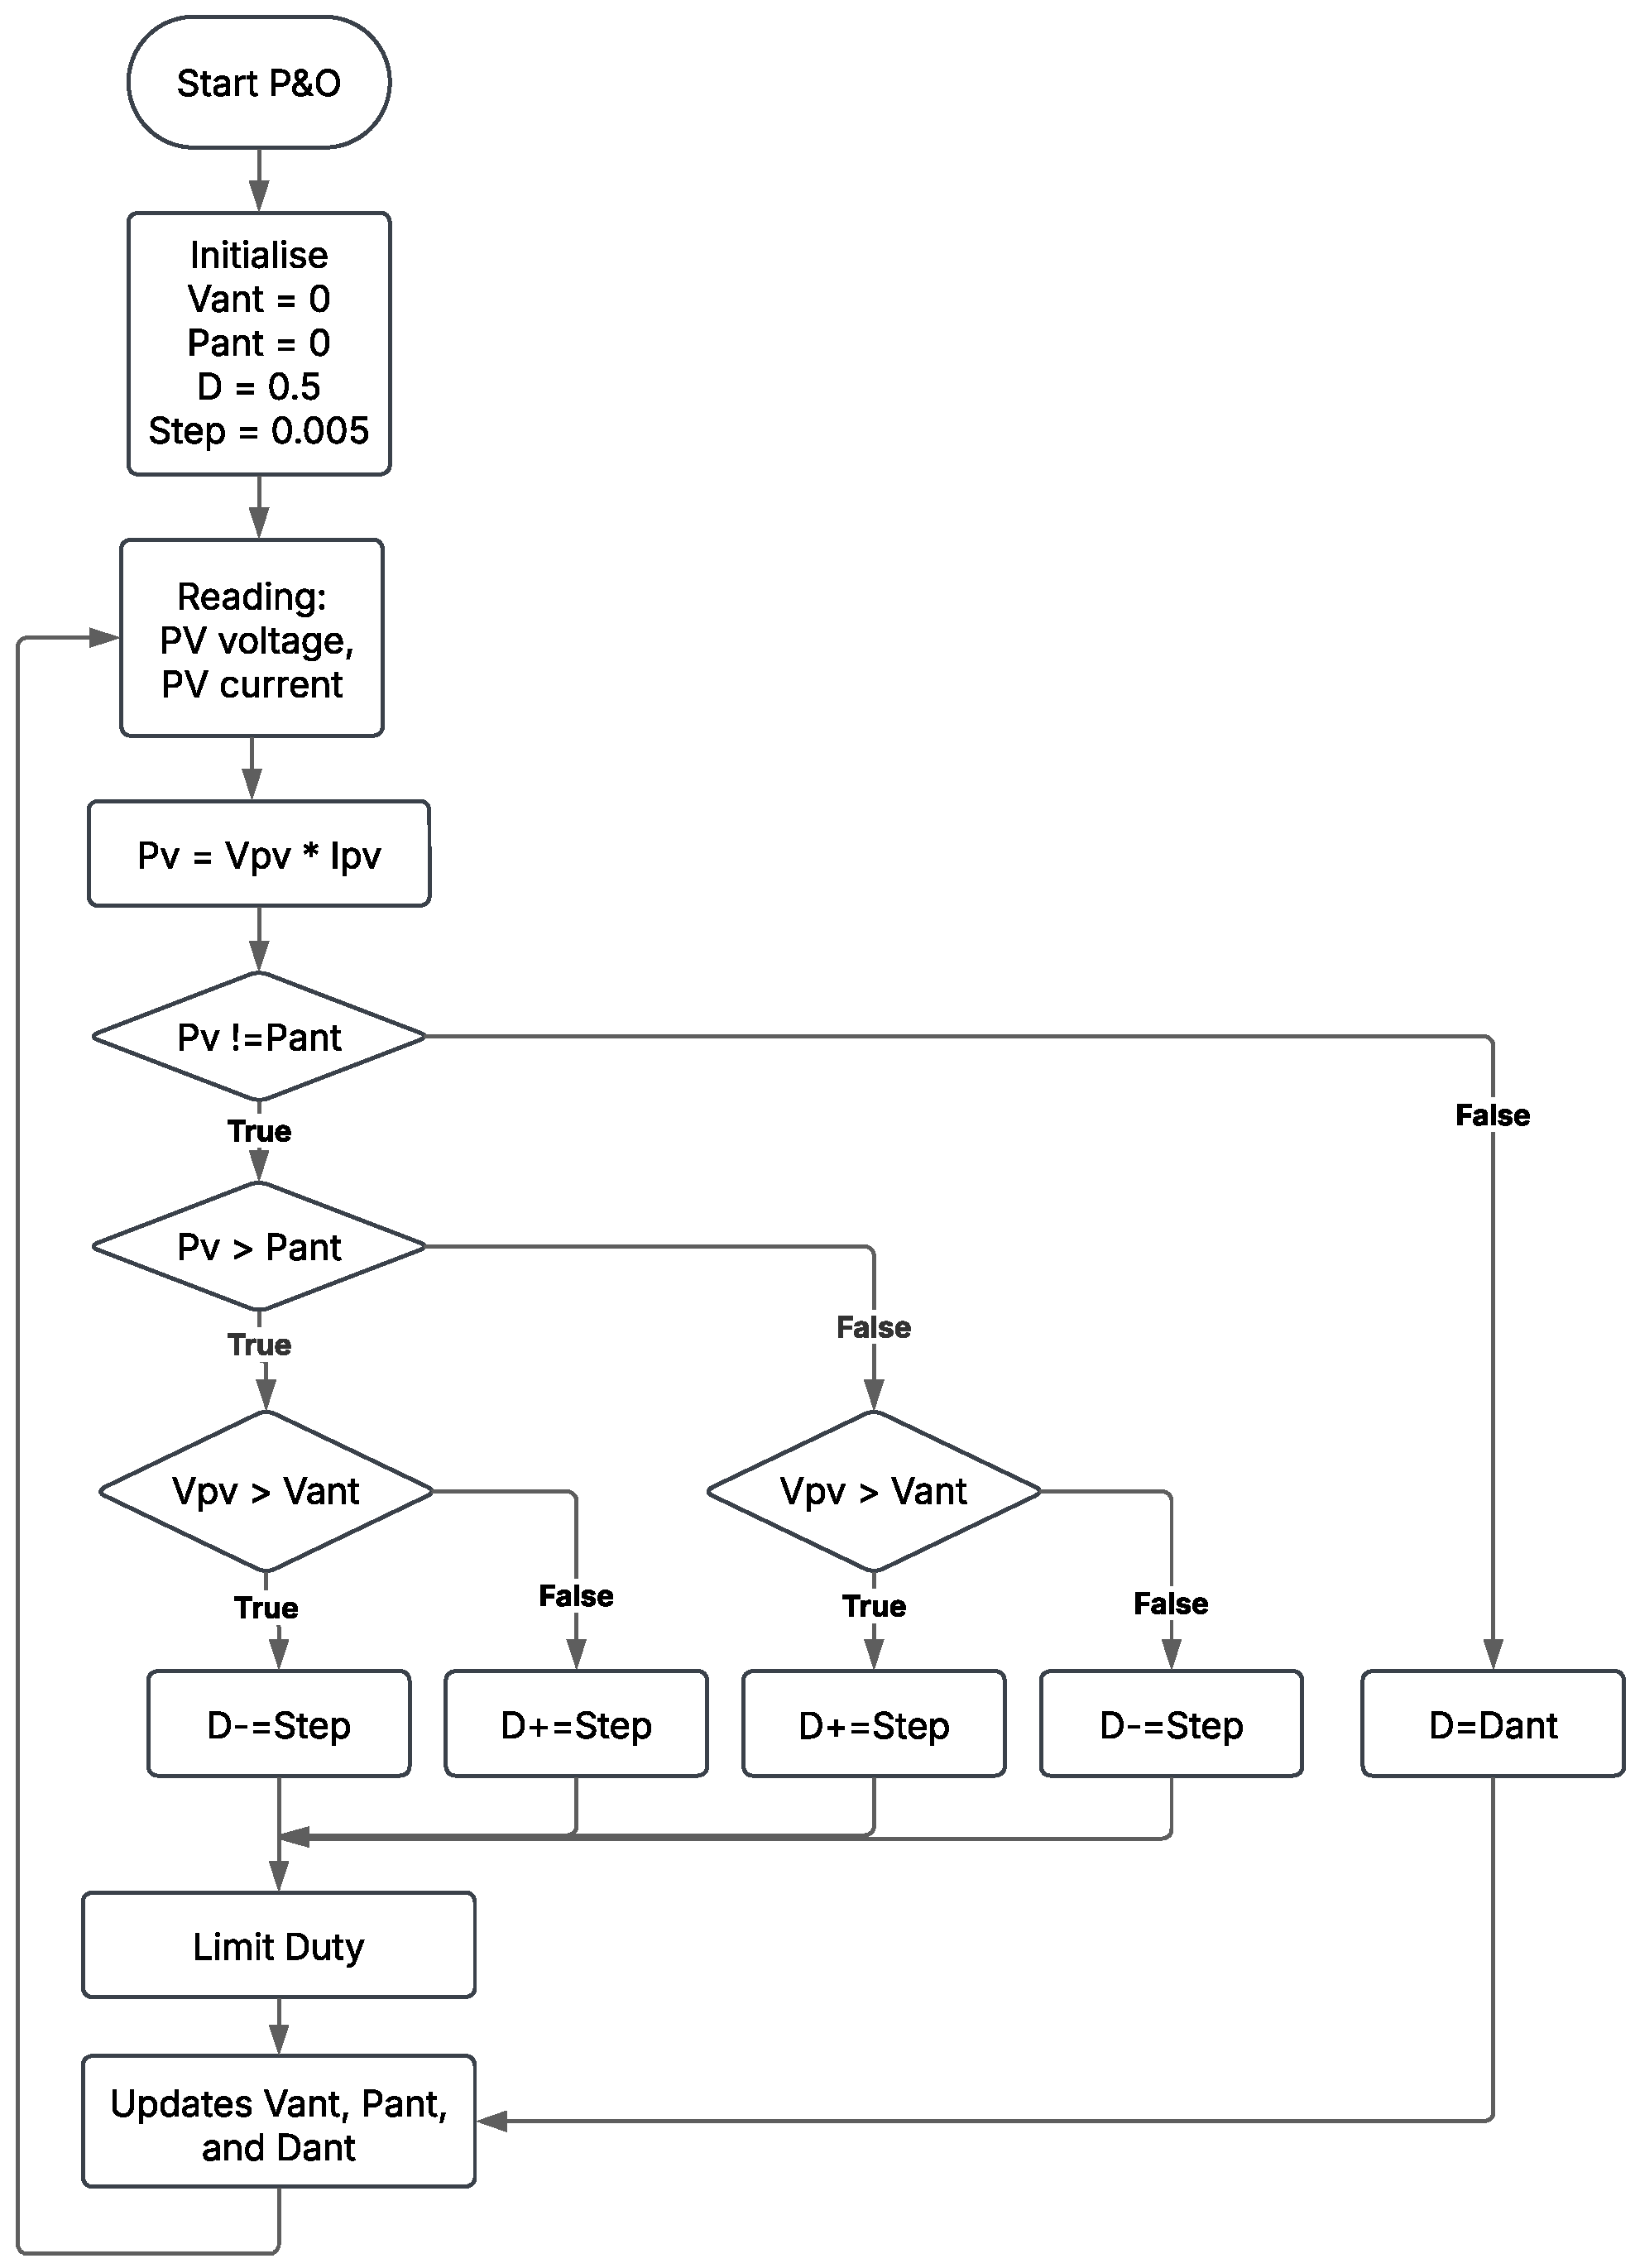
The P&O algorithm is widely adopted in MPPT systems due to its simplicity and low implementation cost. It works by periodically perturbing the voltage—increasing or decreasing it—and comparing the PV output power with the previous perturbation. The logic consists of an iterative trial-and-error process [7,26]. If the change in voltage results in an increase in output power, then the perturbation is maintained in the same direction; otherwise, the direction of the perturbation is applied in the opposite direction [27]. Figure 5 shows the P&O algorithm flowchart.
Figure 5.
P&O flowchart.
For the conventional P&O method with fixed perturbation, a step size value is defined in advance, which plays an important role in MPP tracking. When the step size is too large, the system tends to exhibit significant oscillations around the MPP, reducing energy efficiency. On the other hand, if the step size is too small, then the system response becomes slow, which is especially problematic in variable environmental conditions, such as rapid changes in irradiance or temperature [8,27].
In the conventional P&O method with adaptive perturbation, the tracking process involves dynamically adjusting the perturbation applied to the voltage. Initially, the step size is set to 10% of the open-circuit voltage (Voc), serving as a reference for the variation. This approach provides better performance than the fixed perturbation approach, reducing the response time and oscillations around the maximum [8].
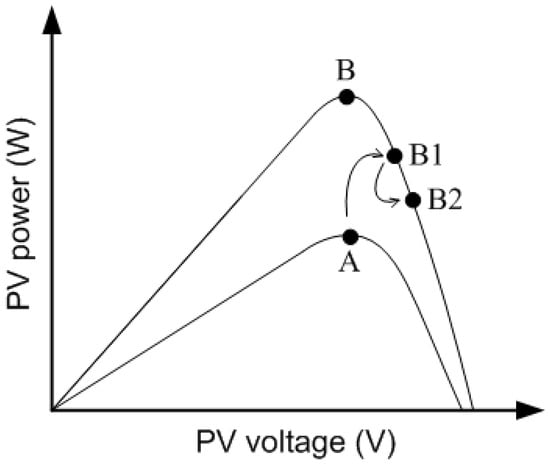
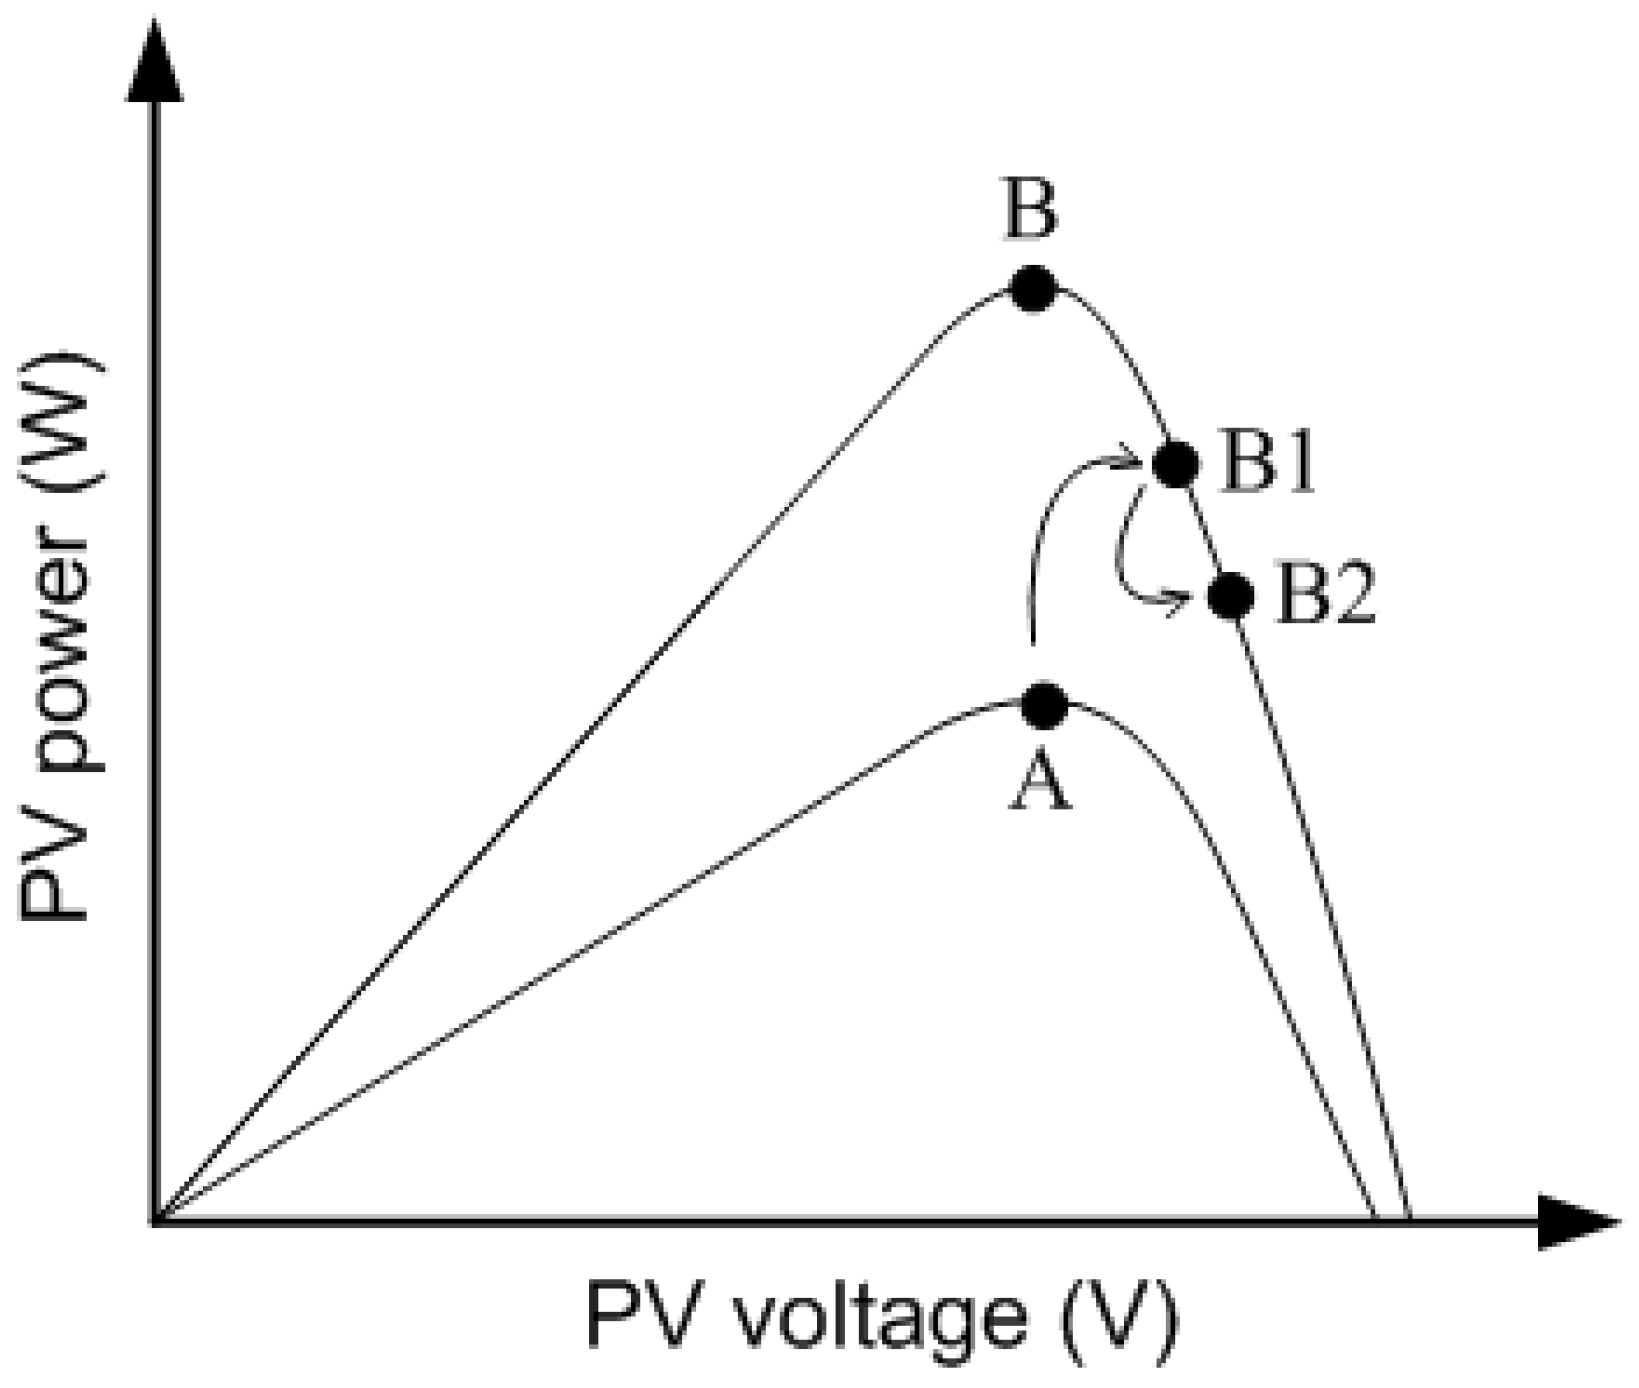
The conventional P&O algorithm tends to fail in partial shading conditions, where multiple local maximum power points may exist. It tends to get “stuck” at an LMPP, which is smaller than the GMPP, because it does not distinguish between local maxima and the global maximum. In addition, this method can cause the system to proceed in the wrong direction when the system is subject to sudden changes in environmental conditions. Consider Figure 6, where the operating point is point A if the irradiance condition changes, and the operating point of the system moves to point B1. At this point, the algorithm checks the power difference, which is B1 − A > 0. Next, the algorithm checks the voltage difference, which is B1 − A > 0, i.e., it assumes that an increase in voltage has led to an increase in power, and thus it will proceed in that direction. This moves the operating point to B2, which is further away from the MPP, which in this case is point B. This phenomenon is called drifting [27].
Figure 6.
P&O performance when environmental conditions change.
2.2. Artificial Gorilla Troops Optimizer (GTO)
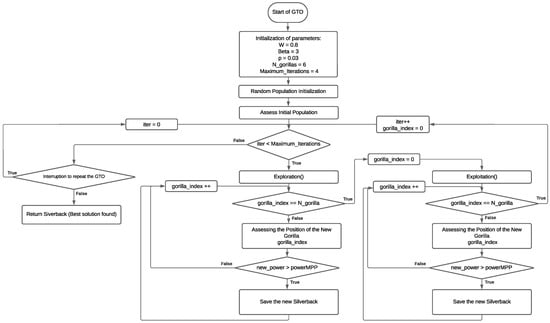
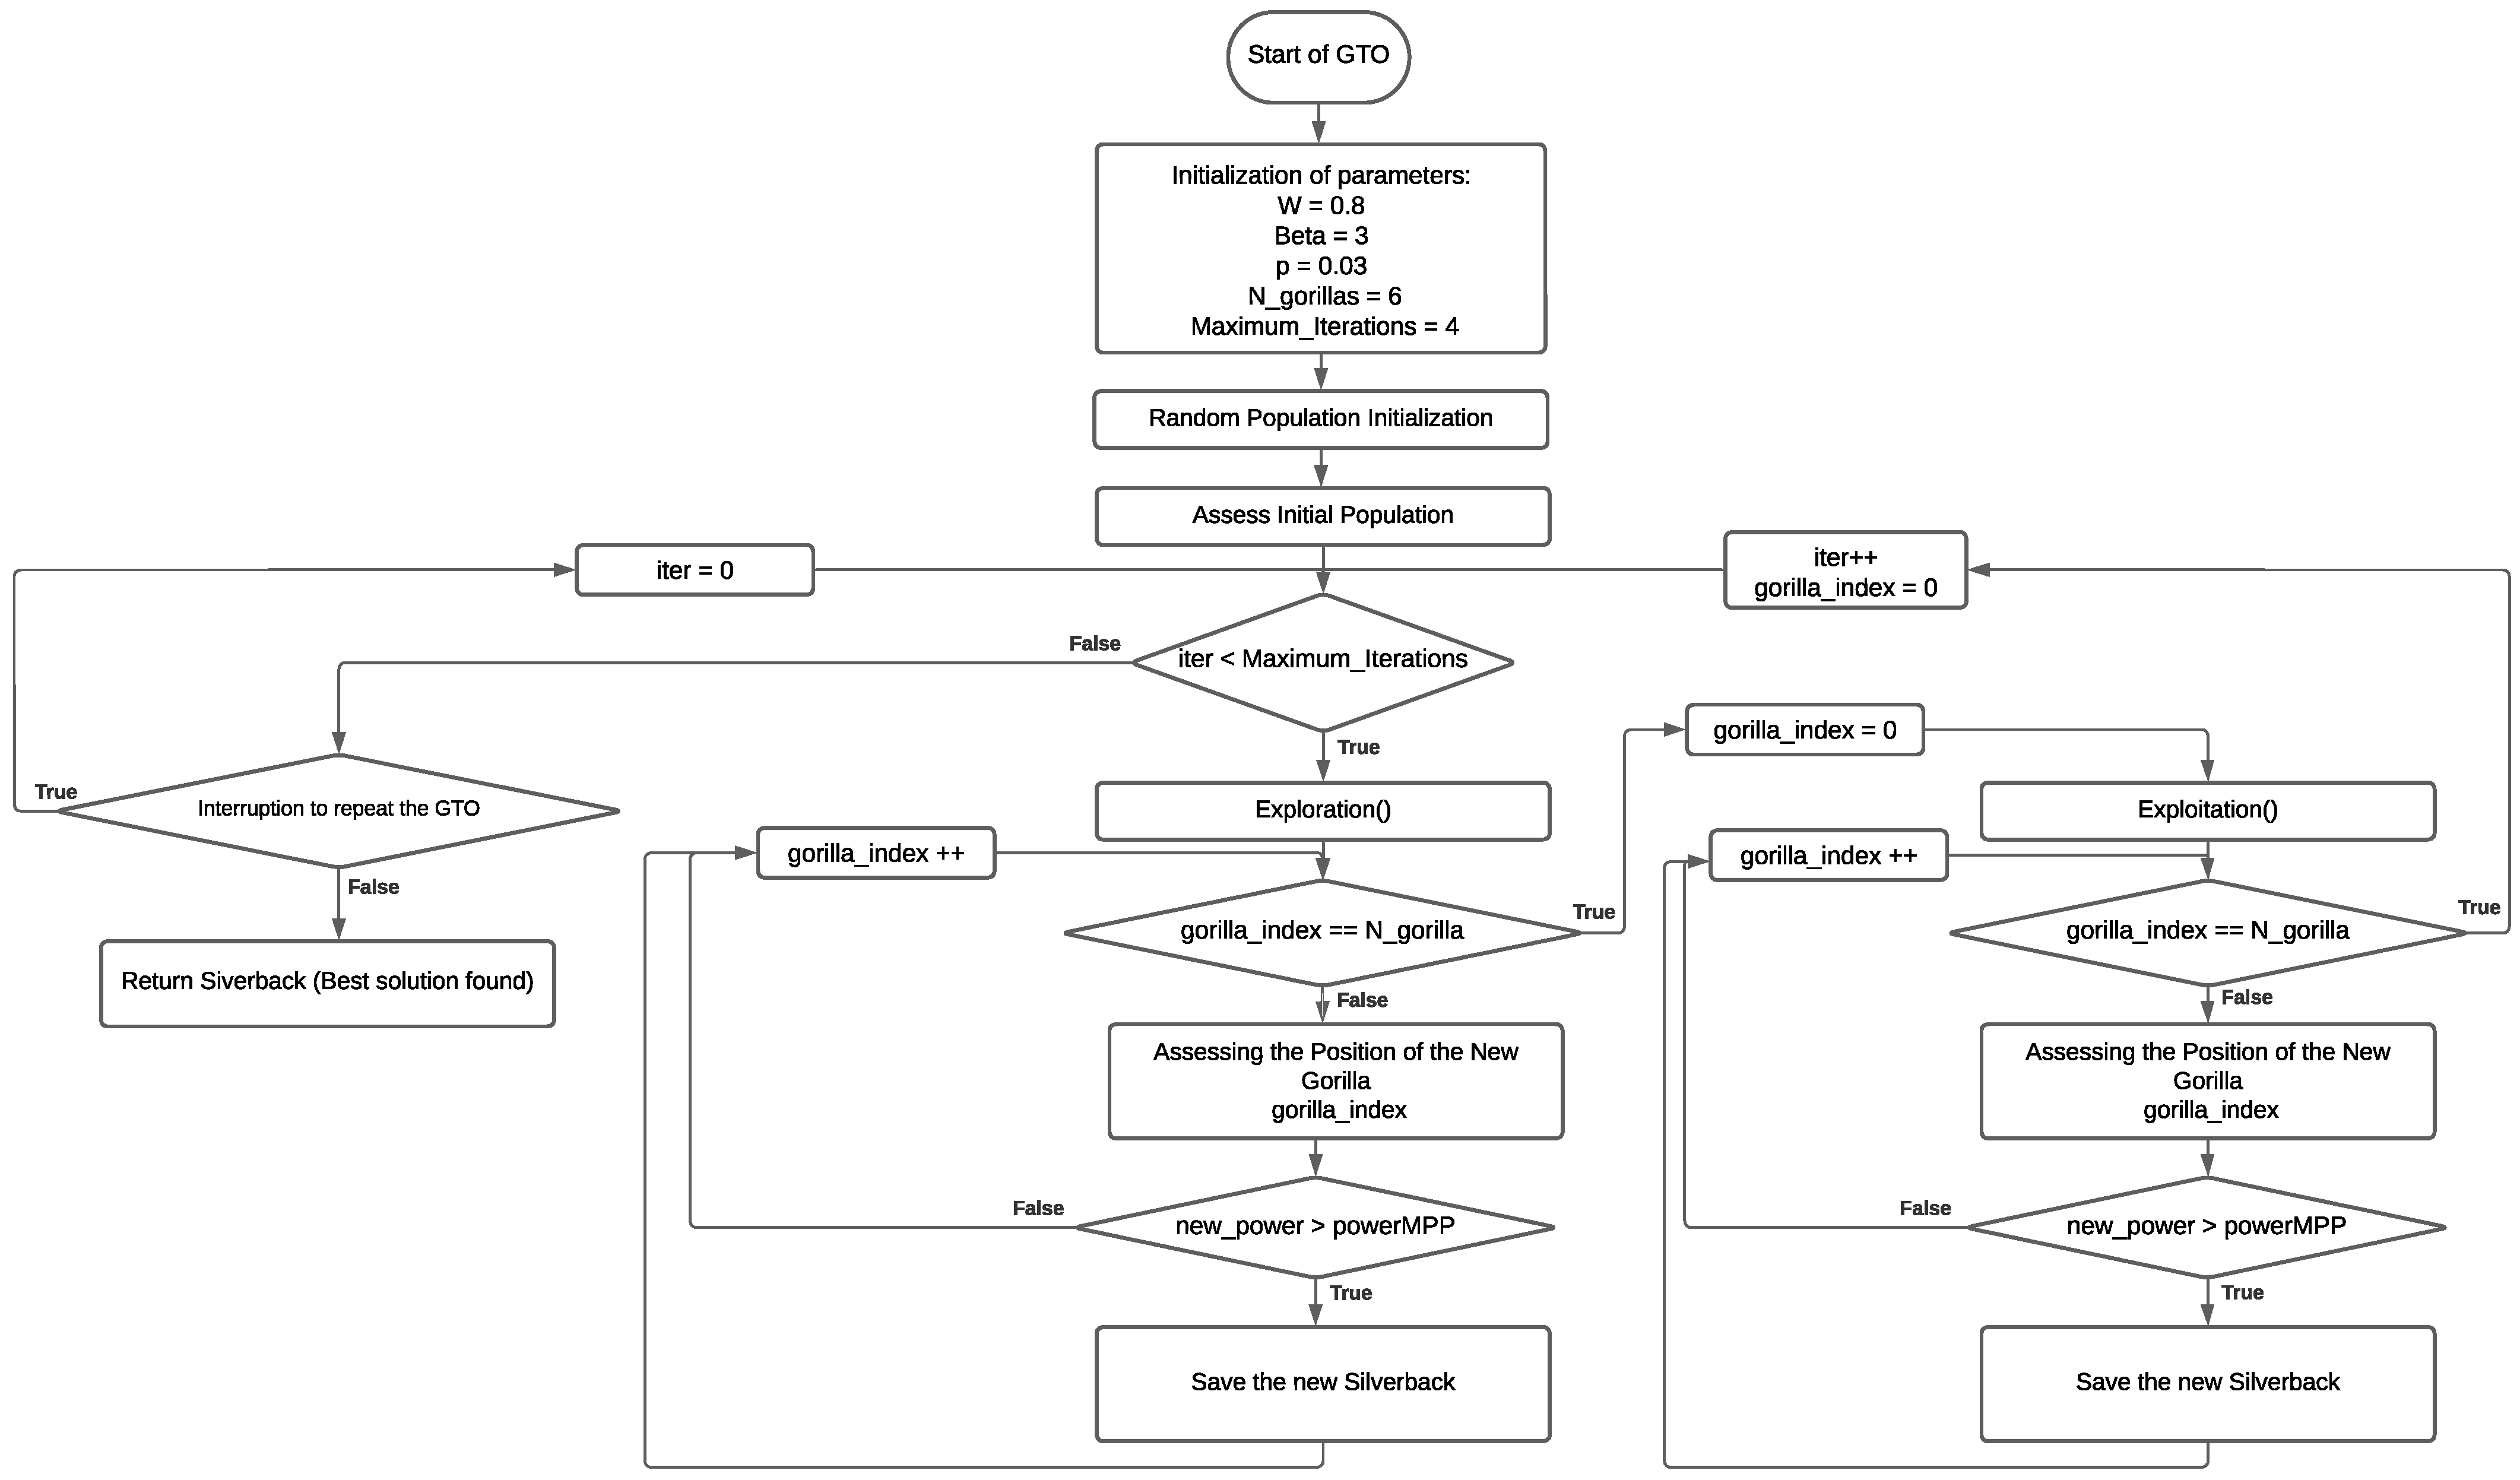
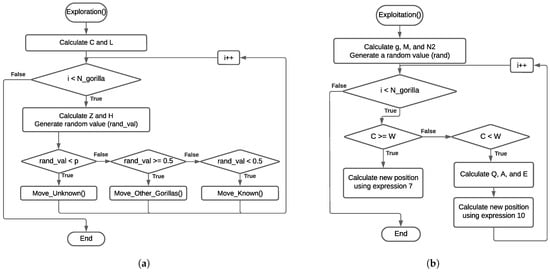
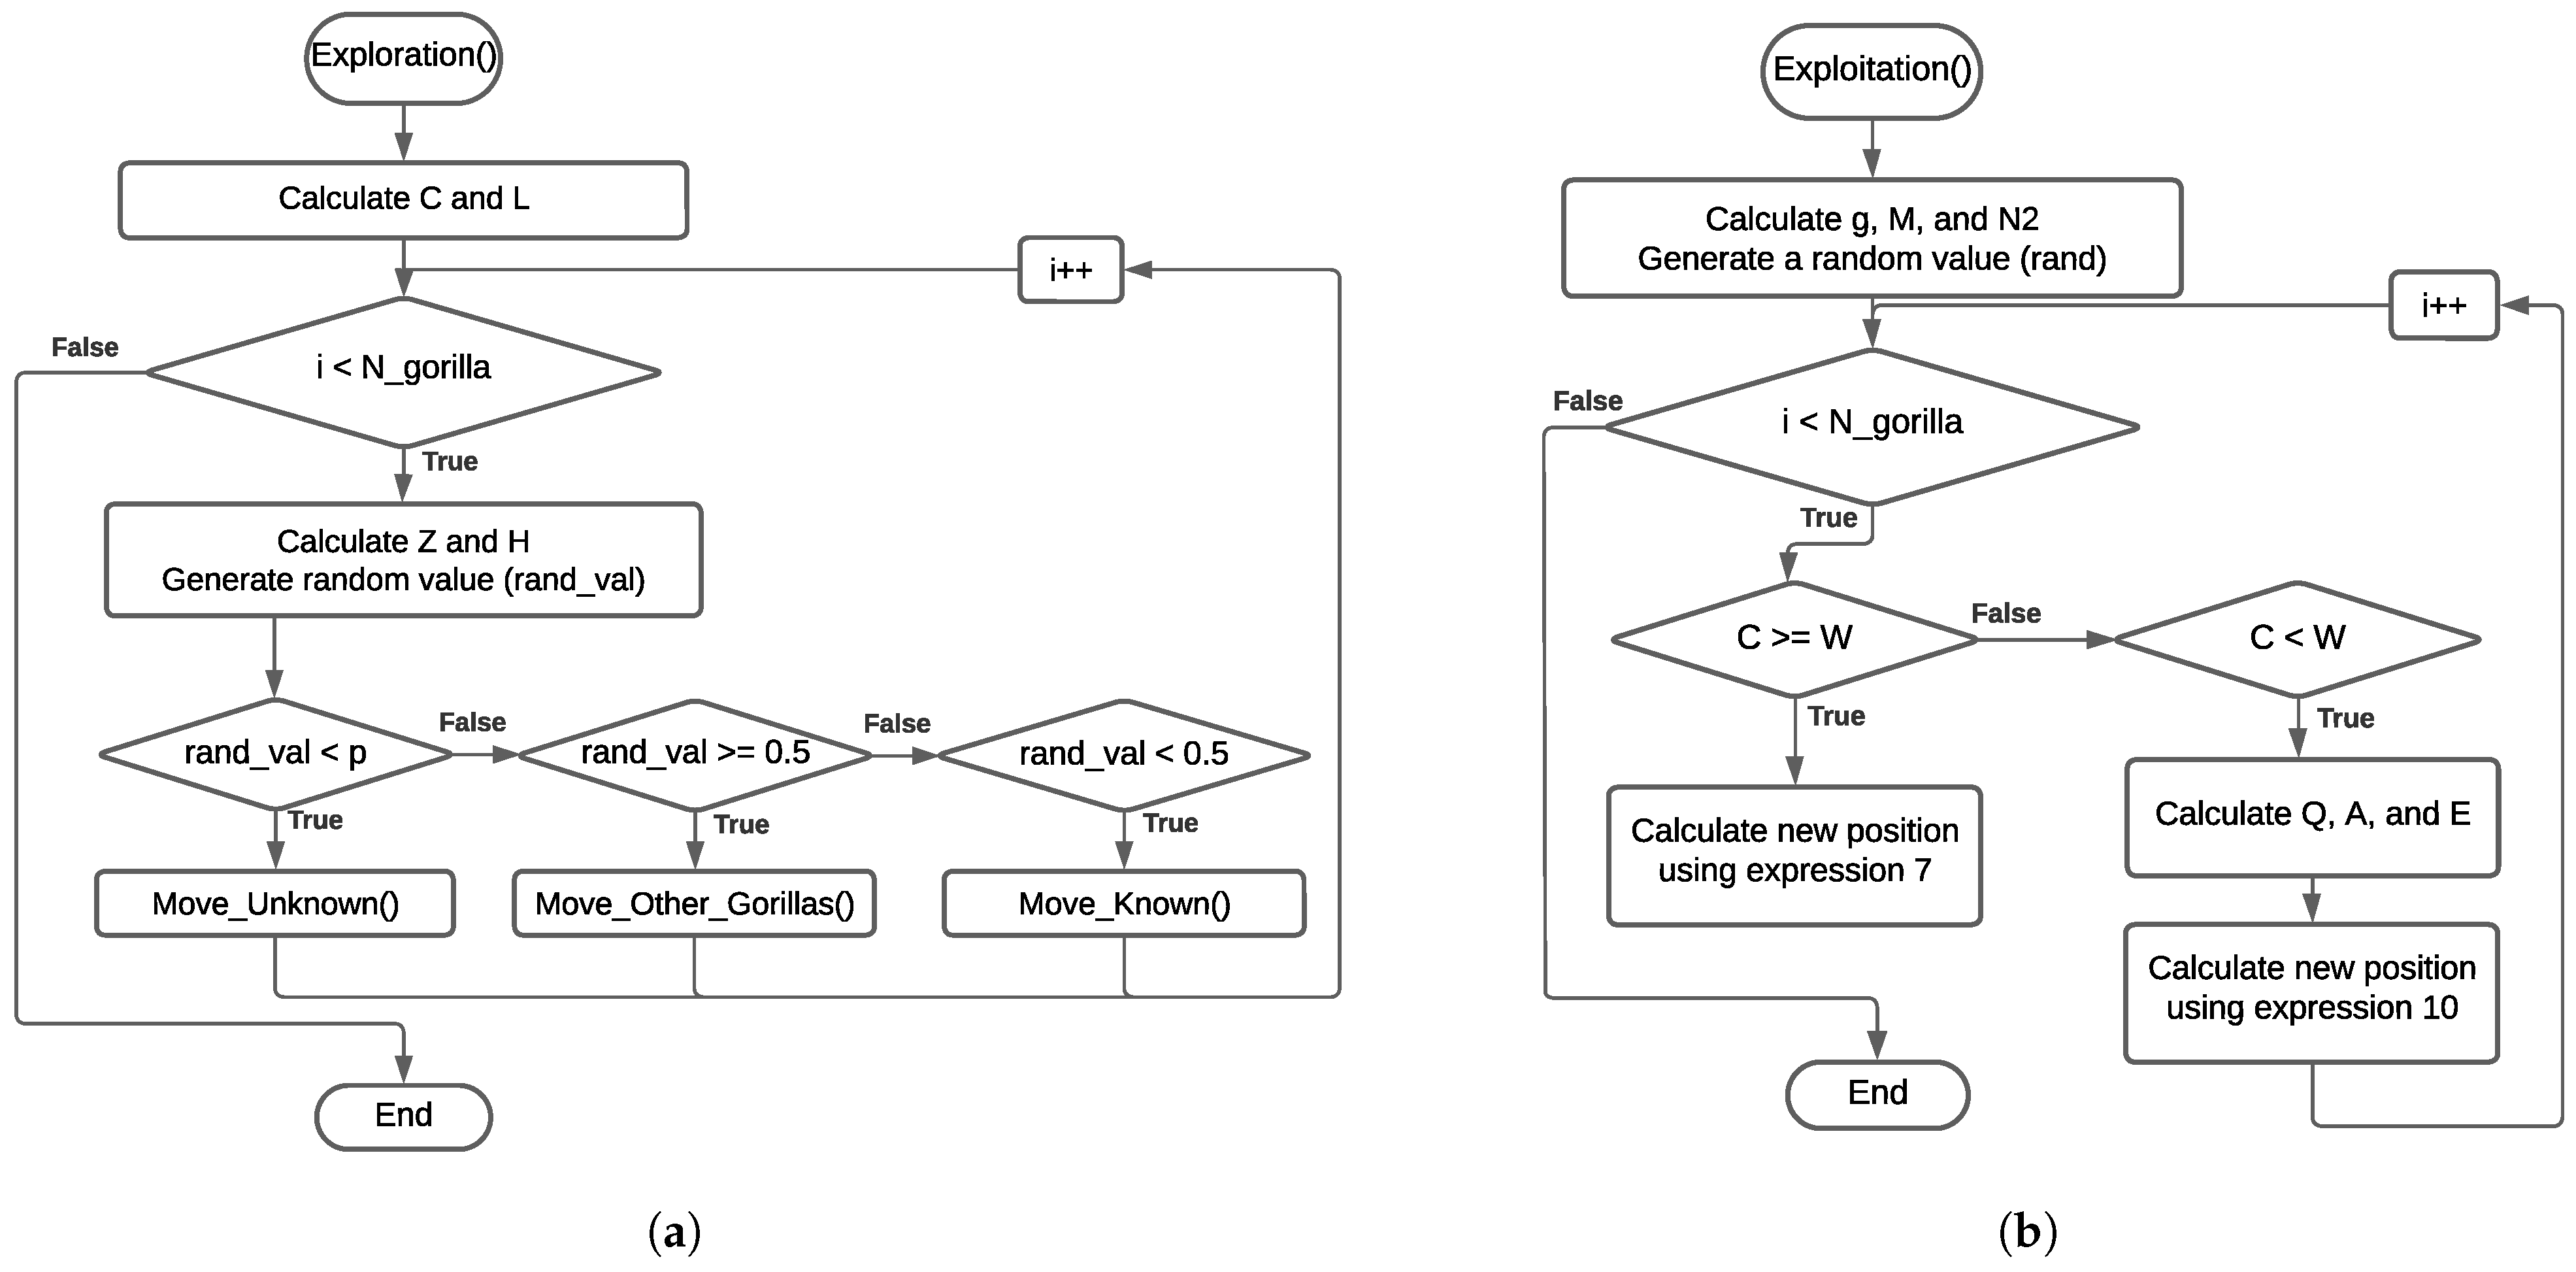
Inspired by the social behavior of gorillas, the artificial Gorilla Troops Optimizer (GTO) [12] emerged in 2021, a meta-heuristic algorithm based on the animal’s behavior in search of food. In this algorithm, the initial population is generated randomly, and using exploration and exploitation techniques, it searches for the best solution according to the objective function of the problem [28]. Since it is a stochastic algorithm, its decisions involve random components, which means that even under the same initial conditions, the final solution may vary between executions. Gorillas are animals that live in groups called troops, where each group has a leader, called a silverback, several females and their offspring. The GTO is applied following this logic. The algorithm can be divided into two distinct phases: the exploration phase and the exploitation phase [28]. The GTO algorithm’s general flowchart is shown in Figure 7. The steps related to the exploration and exploitation phases are described in detail in Figure 8a and Figure 8b, respectively.
Figure 7.
Traditional GTO flowchart.
Figure 8.
Flowchart of the (a) exploration and (b) exploitation phases of the traditional GTO algorithm.
2.2.1. Exploration Phase
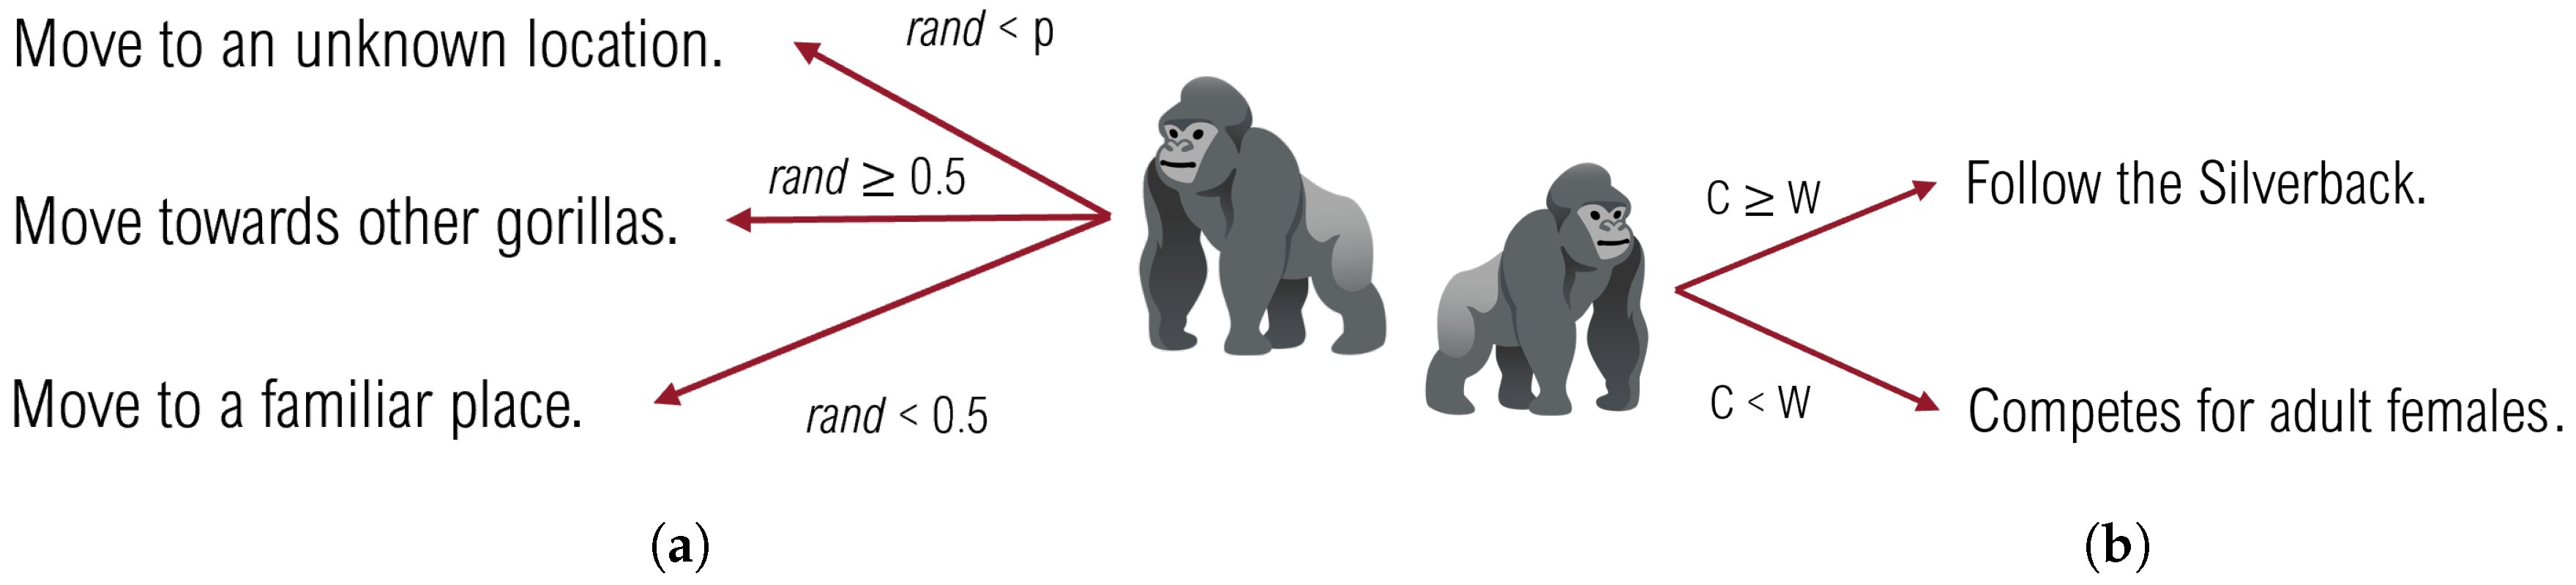
Each gorilla represents a candidate solution, in which the one that provides the best response to the objective function is designated as the silverback, or leader. Gorillas naturally tend to follow this leader, but occasionally they may follow different paths. The movement of the animal within the search space is determined by Equation (1), which is represented graphically in Figure 9a. In this figure, the movement is based on a randomly generated value, rand, between 0 and 1, which determines the behavior in the next iteration according to three possible scenarios [23,28]:
Figure 9.
Movement of gorillas in the different phases of the GTO, namely (a) the exploration phase and (b) the exploitation phase.
- If , where p is defined in advance (typically low, such as 0.03 [23]), then the gorilla moves to an unknown location;
- If , then the gorilla moves toward other gorillas;
- If , then the gorilla moves to a known location.
In the expression, X and represent vectors whose sizes correspond to the previously defined number of gorillas. indicates the gorilla’s candidate position in the next iteration , while refers to its current position. The lower and upper limits of the variables are defined by the lower bound (LB) and upper bound (UB), respectively. The parameters , and are random values generated in the interval [0, 1]. The notations and represent the positions of randomly selected gorillas. The parameters C, L and H are calculated according to Equations (2), (4) and (5), respectively, as indicated in [23,28]:
In the presented expressions, the variables t and represent the current iteration and the maximum number of iterations defined, respectively. The variables and l are both random. The variable takes values between 0 and 1, while l varies between −1 and 1 [23,28].
2.2.2. Exploitation Phase
In the second phase of the algorithm, the gorilla can adopt two behaviors: follow the silverback or compete for adult females, aiming to explore promising regions of the search space. This decision is based on the value of C, calculated previously according to Equation (2), in comparison with W, which must be predefined [23,28].
The value of W plays an important role in balancing the convergence time and exploration of the search space. A low value implies a greater tendency to follow the silverback, i.e., convergence will be faster. However, a low value can impact the exploration of the search space, which can lead to the real optimum point not being tracked. Conversely, a high W value encourages competitive behavior on the part of the gorillas, increasing the exploration of the search space, which leads to a slower algorithm in terms of convergence. The correct definition of the value of W is one of the challenges of the problem. According to some studies [12,23,28,29], the most common value is between 0.8 and 1.
If the value of C is equal to or greater than W, then the gorilla follows the silverback, respecting Equation (7). Otherwise, it chooses to compete for females, in accordance with Equation (10). represents the best solution found (silverback position), and M and L are calculated according to Equations (8) and (9), respectively. The gorilla’s movement is represented graphically in Figure 9b:
The total number of gorillas is defined as N, and represents the position of each gorilla in iteration t [13].
In the above expressions, the variable Q represents the magnitude of the applied force, which is influenced by the parameter , a random value between 0 and 1. The variable A corresponds to the level of intensity of the conflict, which is defined based on previously established parameters, namely and E. The term E, in turn, is randomly generated according to the dimensions of the problem, adopting values from a normal distribution when (where is a random number between 0 and 1). Otherwise, a different random value is assumed which is still within the normal distribution range. The parameter must be predefined, directly influencing the search dynamics of the algorithm. Lower values of favor a more comprehensive exploration of the solution space, leading to slower convergence. In contrast, higher values for result in accelerated convergence, albeit at the expense of a reduced exploration capacity. In the studies presented in [12,29], it was decided to set .
Table 1 summarizes the parameters that the user must select before running the GTO, also highlighting the impact of each parameter and the recommended values according to the literature.
Table 1.
GTO parameters and their influence.
3. Simulations
The techniques described above were subjected to the same environmental conditions to compare them. The simulations presented here were carried out using PSIM software (Altair Engineering Inc., Troy, MI, USA), which is specifically designed for power electronics applications.
Among the various solar panel options available on the market for the project, the 5 W panel from the manufacturer XUNZEL was chosen. All of its characteristics can be found in Table 2. Low-power converters are relevant for Internet of Things or energy harvesting applications. The 5 W prototype serves as a proof of concept to validate the EnGTO’s ability to handle rapid atmospheric changes and PSCs without the safety risks and costs associated with high-voltage testing. Above all, the GTO algorithm operates on the search space of the duty cycle, which is always bounded between 0 and 1, regardless of the panel’s power.
Table 2.
Features of the solar panel used (SOLARPOWER-5W).
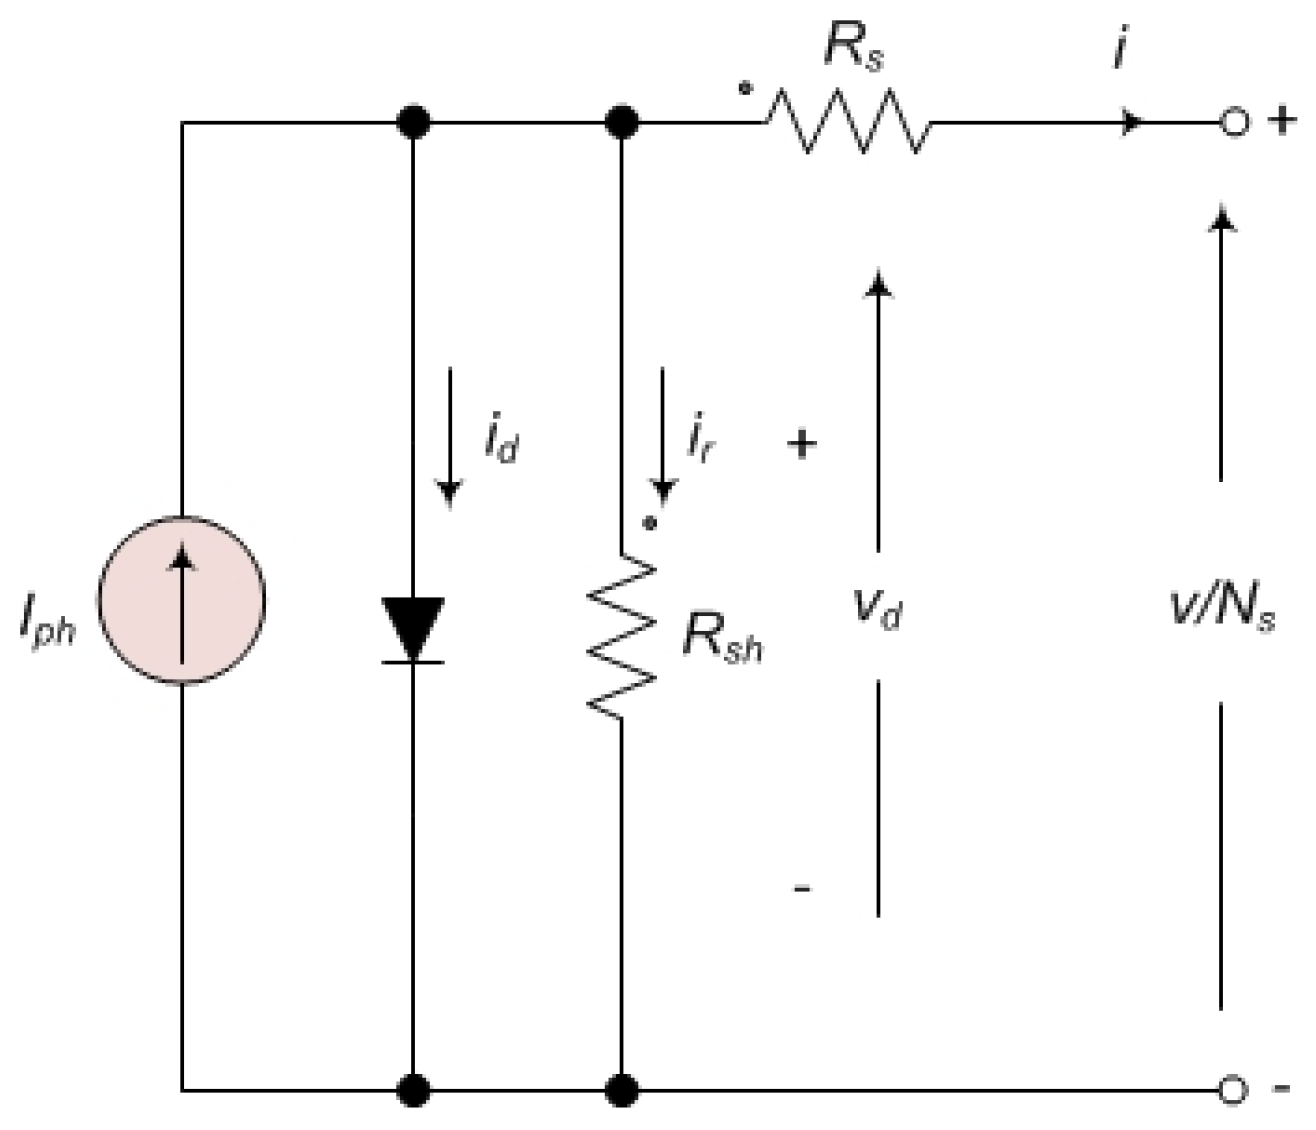
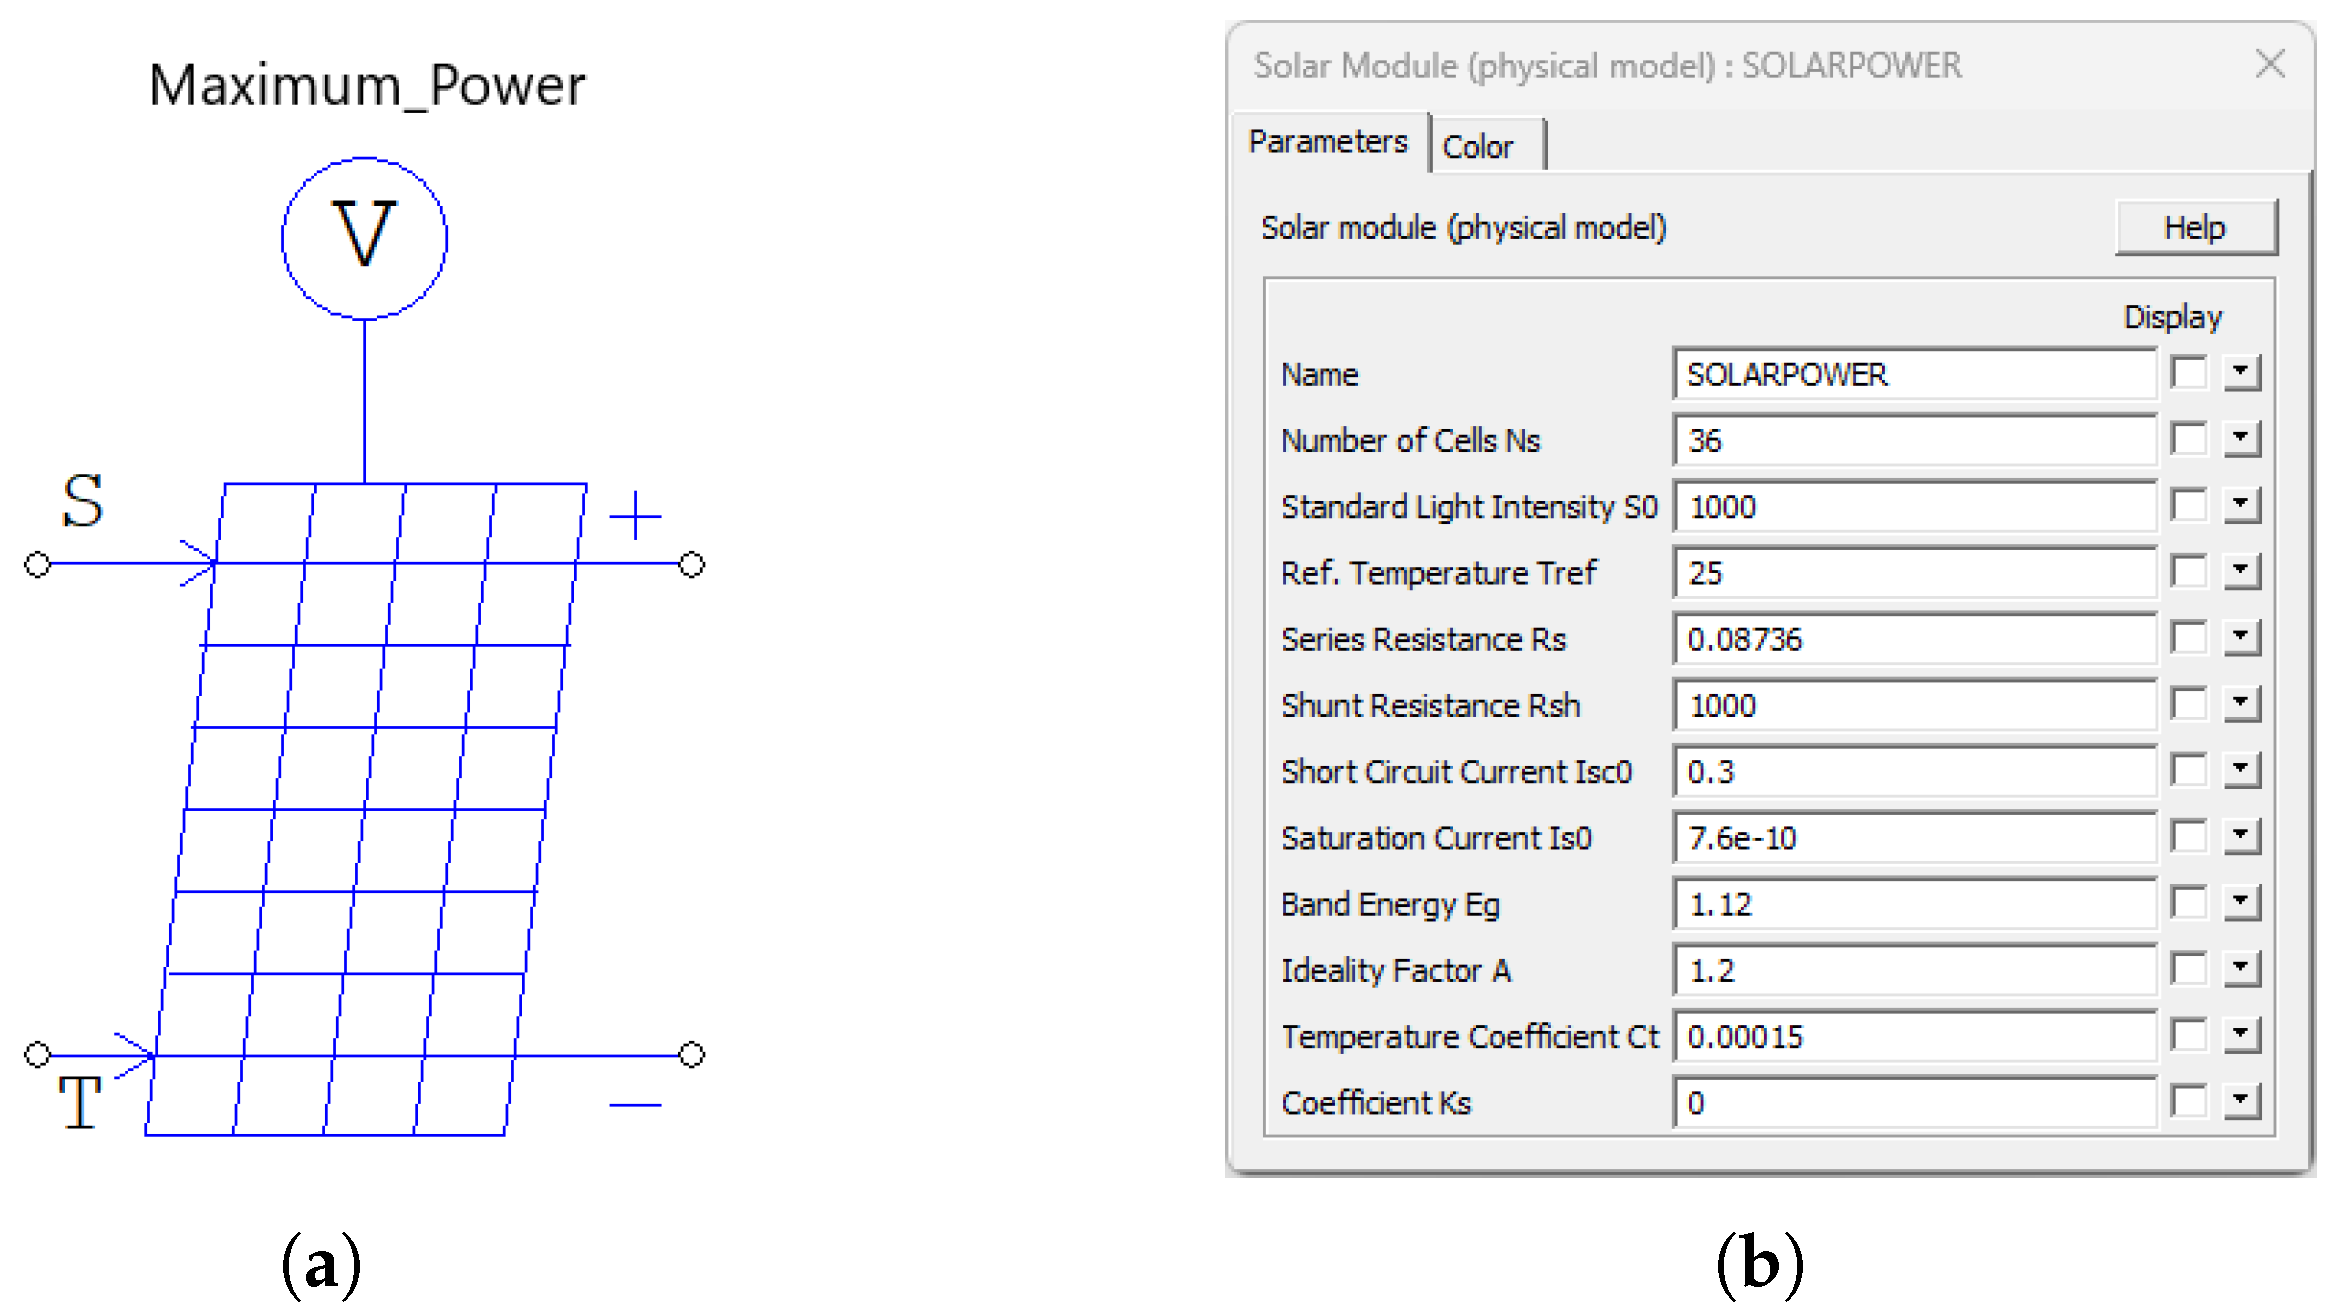
The PSIM software provides, in its library, a physical model of a PV panel—called a solar module (physical model)—which was used in the simulation of the PV in question. This model allows, through data collected in the manufacturer’s datasheet, calculating the parameters of the panel’s electrical model. In PSIM, the panel is modeled as a set of N photovoltaic cells connected in series, with the behavior of each cell described by an equivalent electrical circuit, as illustrated in Figure 10.
Figure 10.
PV panel’s equivalent electrical circuit.
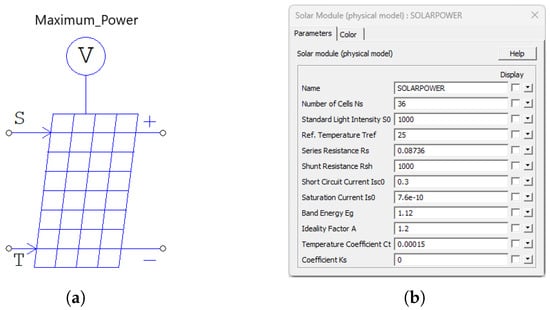
The physical model, shown in Figure 11a, enabled the simulation of different weather conditions, allowing variation in parameters such as the irradiance (S) and temperature (T) and influencing the panel’s MPP. As the maximum power can be determined in real time, it becomes feasible to assess if the implemented MPPT algorithm is operating correctly. The obtained parameters of the SOLARPOWER-5W model are shown in Figure 11b.
Figure 11.
PV simulation in PSIM: (a) PV panel and (b) SOLARPOWER model parameters.
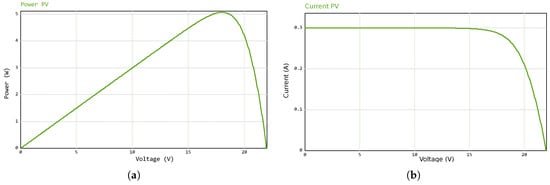
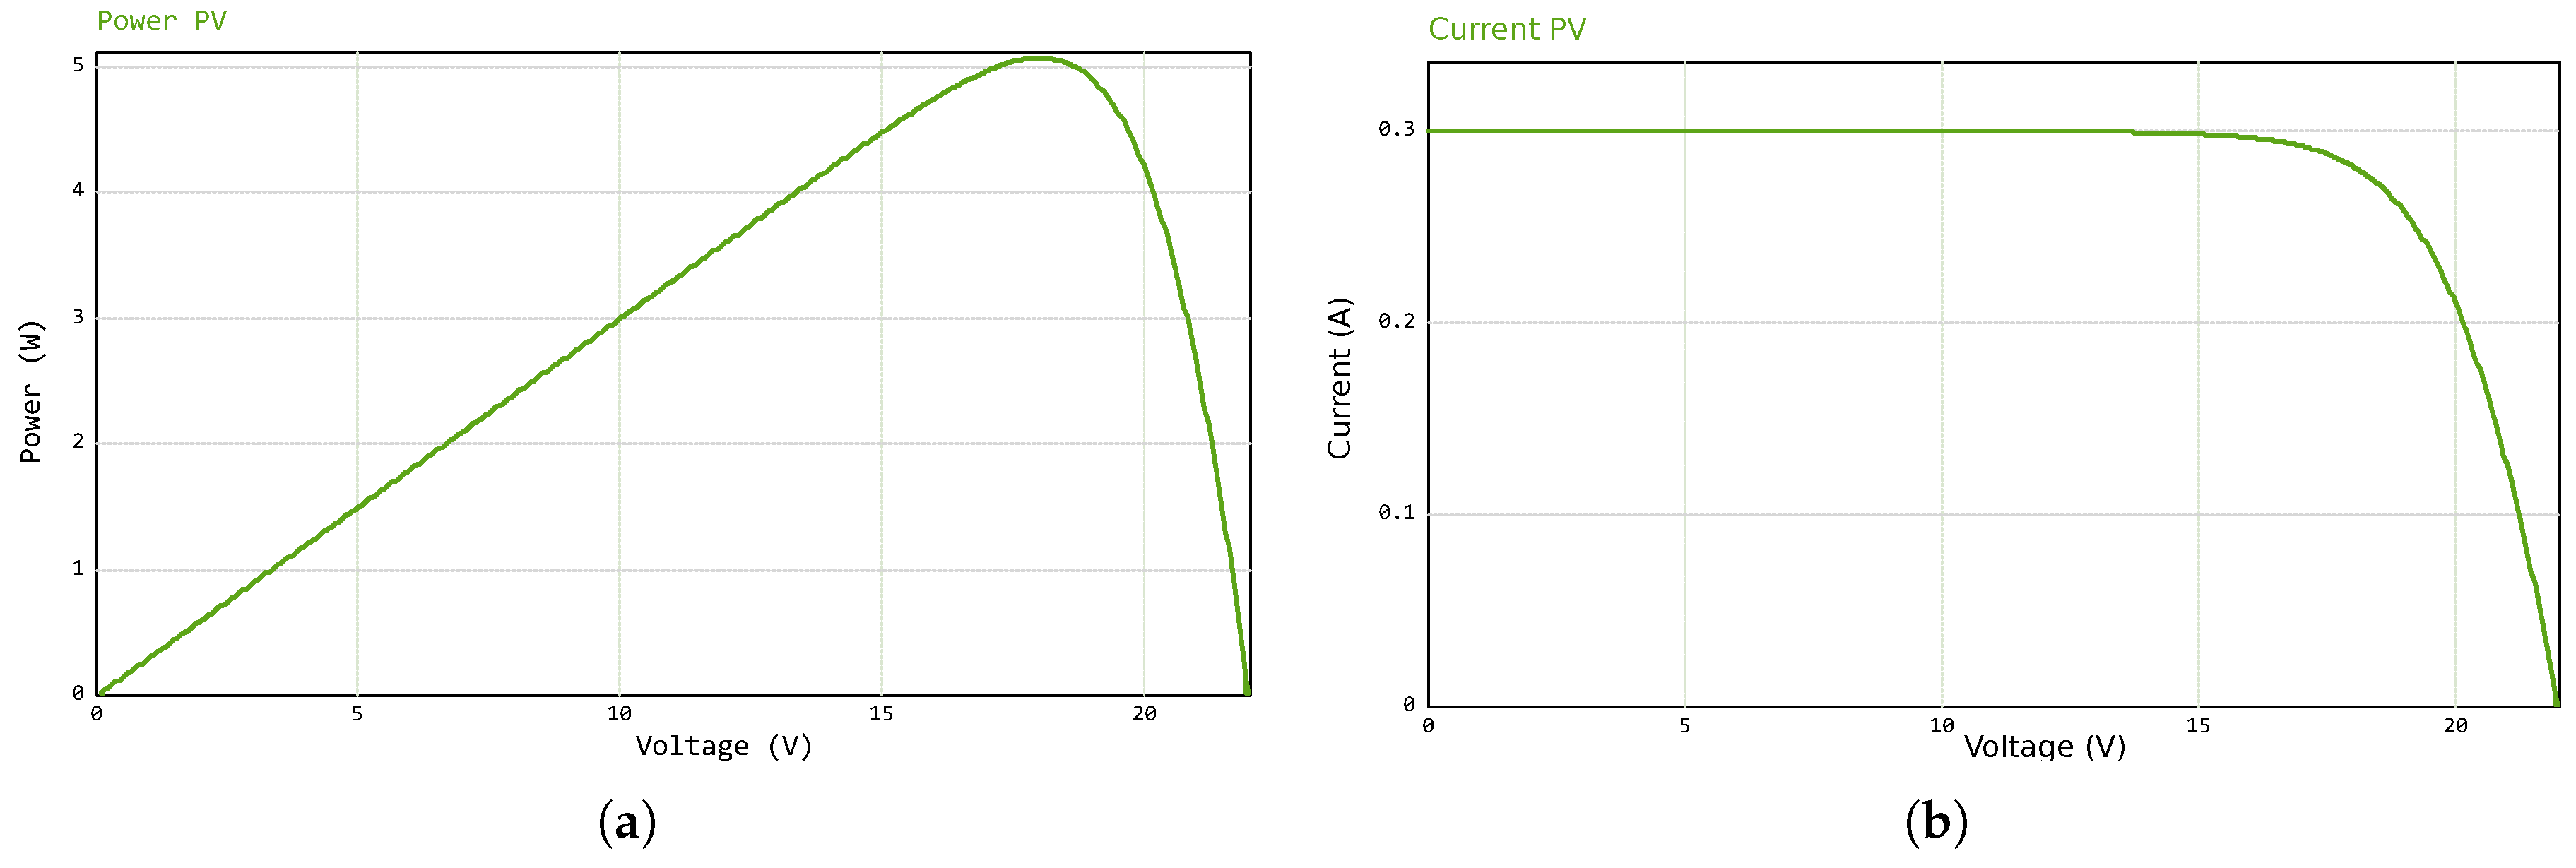
At this stage, simulations of the characteristic curves of the photovoltaic panel were performed under standard test conditions (STCs), corresponding to an irradiance of 1000 W/m2 and an ambient temperature of 25 °C. Figure 12a shows the P-V curve, while Figure 12b shows the I-V curve.
Figure 12.
Panel curves used under STCs: (a) P-V curve and (b) I-V curve.
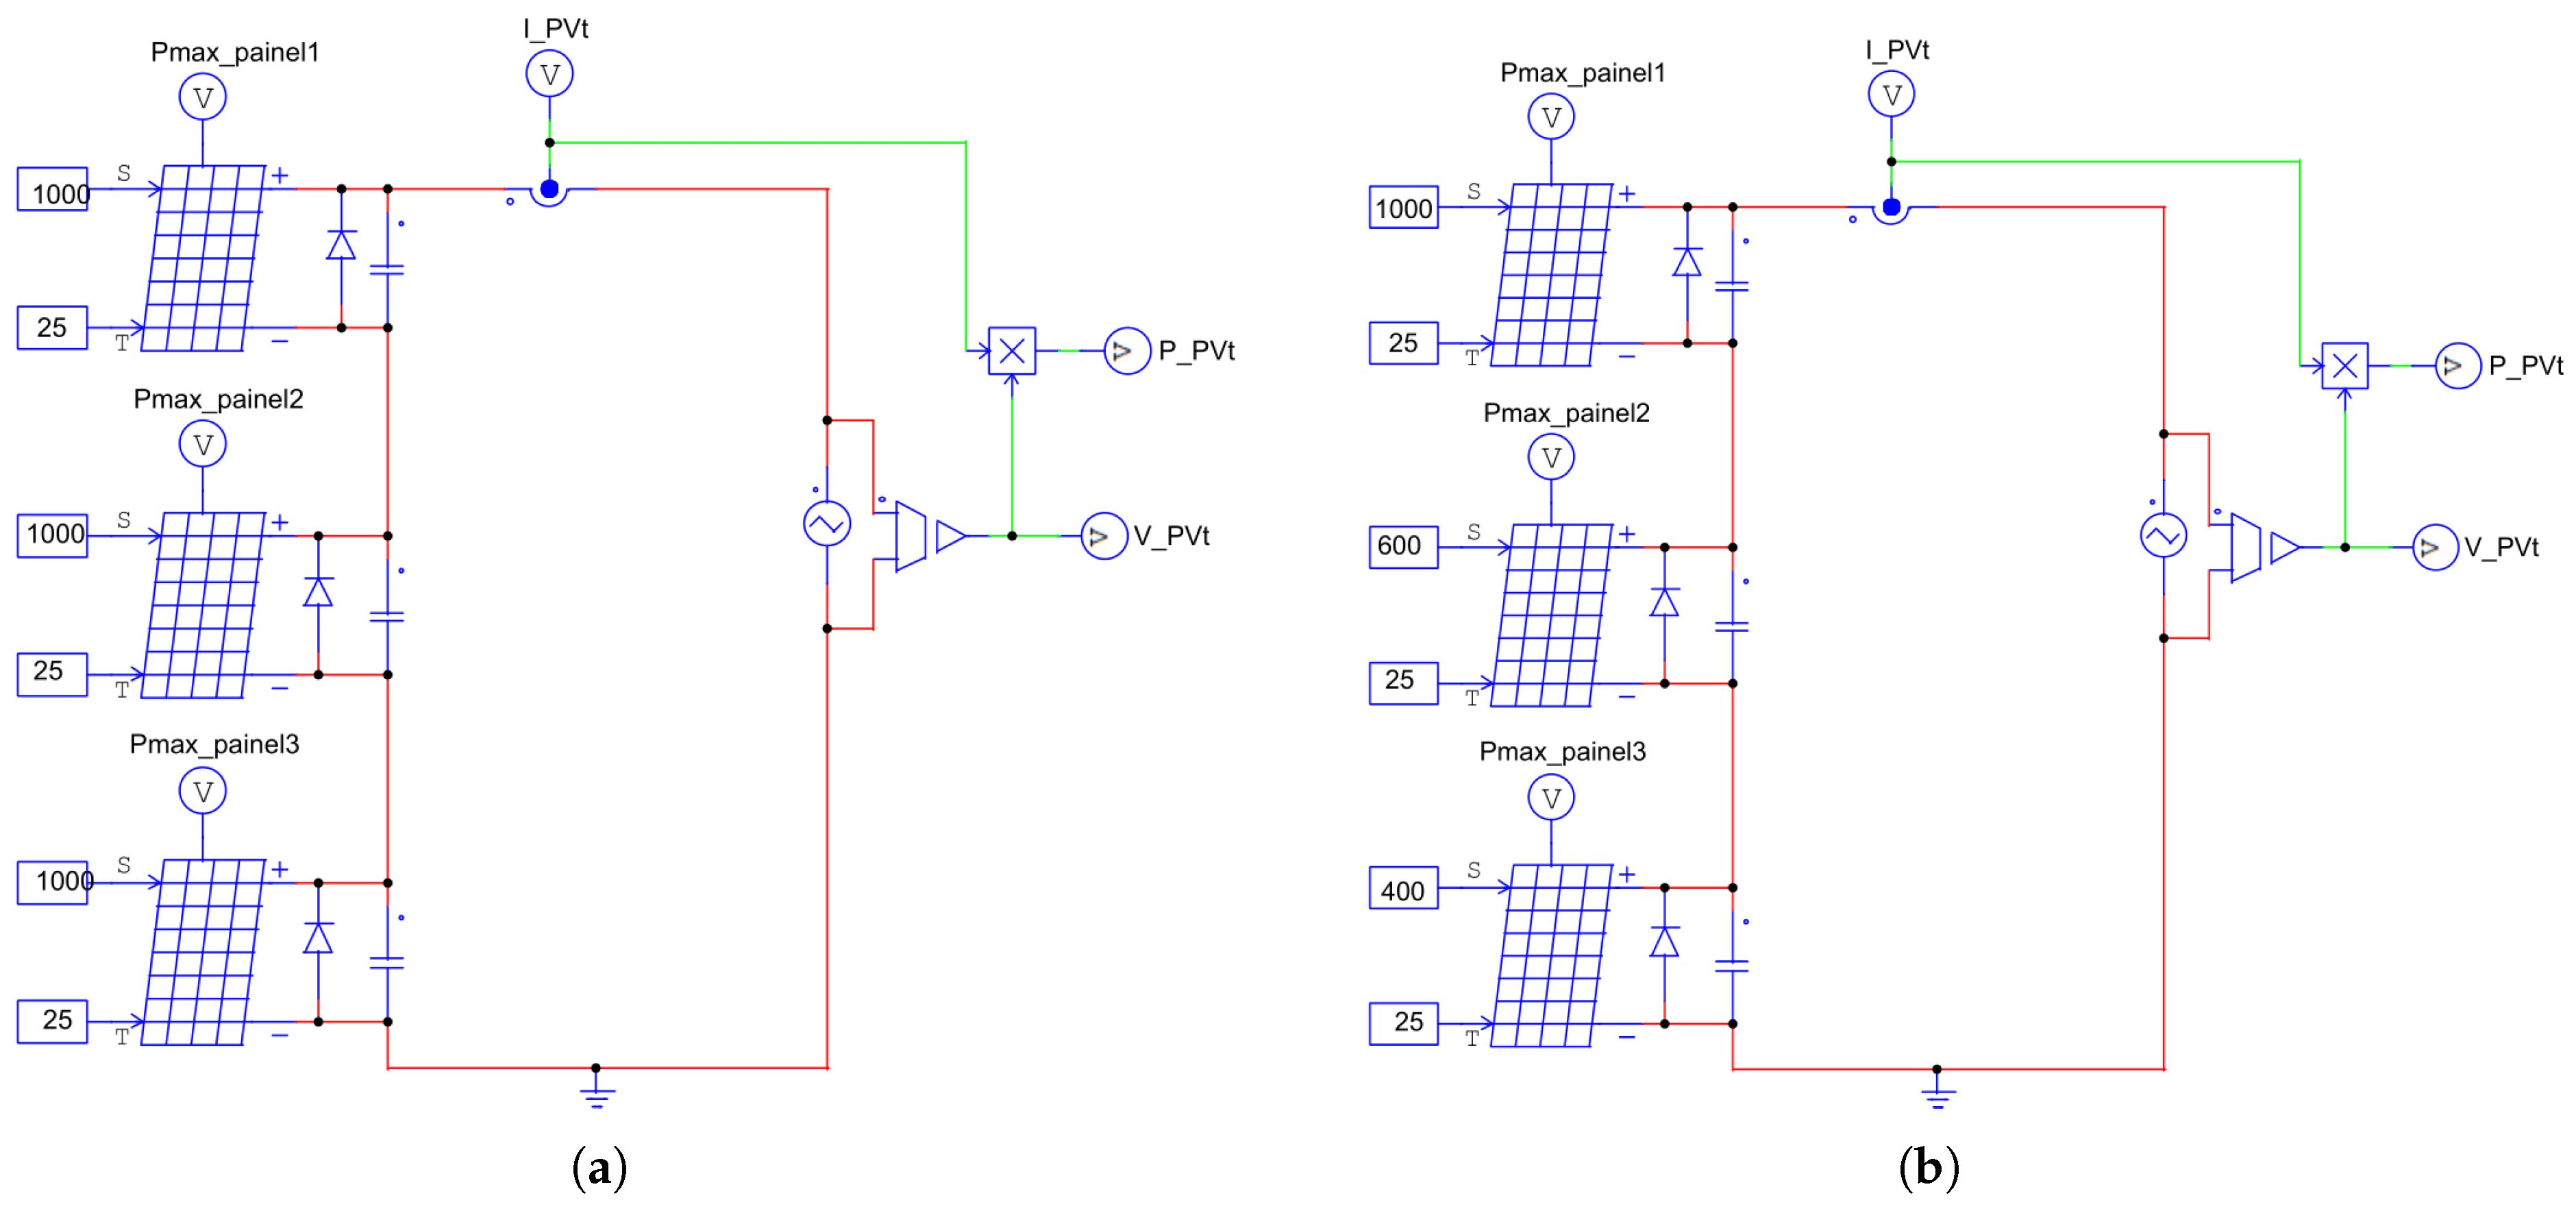
To simulate PSCs, three photovoltaic panels with the characteristics described in Table 2 were considered while connected in series. A bypass diode and a capacitor were inserted in parallel with each panel. The capacitor was used to avoid convergence problems in the PSIM simulation. The bypass diodes had the main function of providing a bypass path for the current if any cell became shaded or failed. This prevented shaded cells from negatively affecting the power extracted from the panel. Without these diodes, a shaded or defective cell would compromise the performance of the entire panel [5].
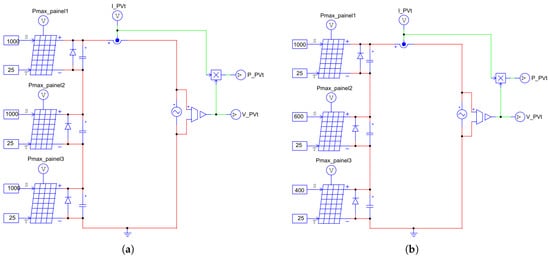
Figure 13a shows the circuit used when all PVs operated under STCs. On the other hand, Figure 13b shows a PSC scenario where the three panels were exposed to different levels of irradiance, specifically 1000 W/m2, 600 W/m2 and 400 W/m2, all maintained at a constant temperature of 25 °C. The panels were connected to a voltage source ranging from 0 to 66 V, considering that each panel had a maximum open-circuit voltage of 22 V. Thus, it was possible to simulate all the operating conditions of the series, allowing analysis of the system’s response across the entire range of voltages it could present.
Figure 13.
Simulation of the PSC in PSIM, using three panels connected in series: (a) under STCs and (b) with PSCs with different irradiances for each panel.
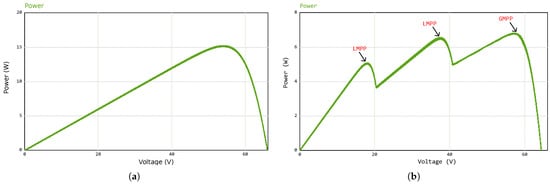
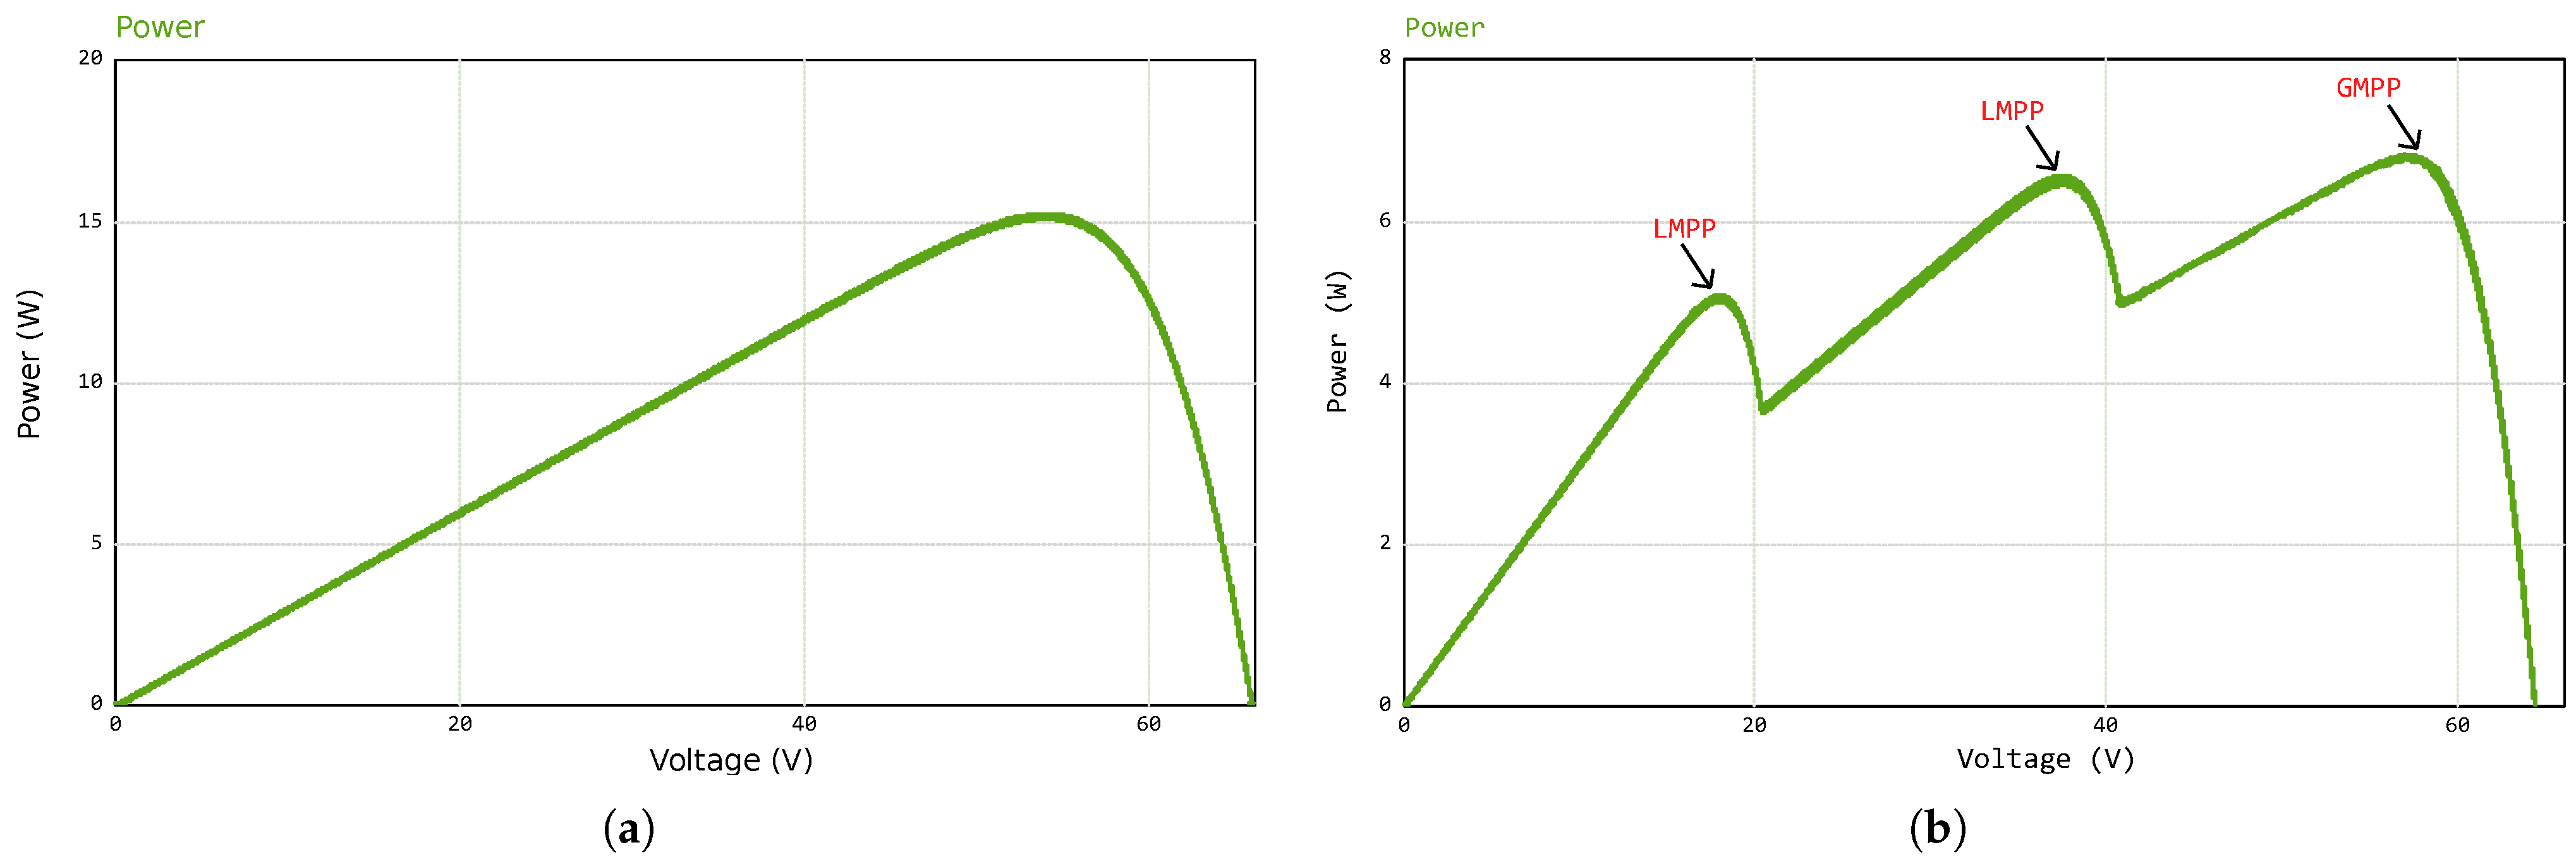
The P-V curves of the circuits analyzed are shown in Figure 14. In Figure 14a, a maximum power of 15 W (3 (panels) * 5 W) was expected, which was confirmed. In the PSC, two LMPPs and one GMPP were observed, as shown in Figure 14b.
Figure 14.
P-V curves for the three panels for (a) STC and (b) PSC.
3.1. DC/DC Buck Converter
With the photovoltaic panel properly modeled, the next step was to design the converter to which the PV system would be connected. For the purposes of this research, a Buck-type converter was chosen. Table 3 lists the select specifications to design the Buck converter.
Table 3.
Buck converter specifications.
Using well-known equations to design this type of converter, the values listed in Table 4 were obtained, which also shows the parameters adopted in the simulation. Regarding the input capacitor Cin, according to [30], to smooth the PV voltage, it is necessary to use it due to the nonlinearity of its characteristics. Its value is obtained according to Equation (14).
Table 4.
Calculated values and selected components for the converter.
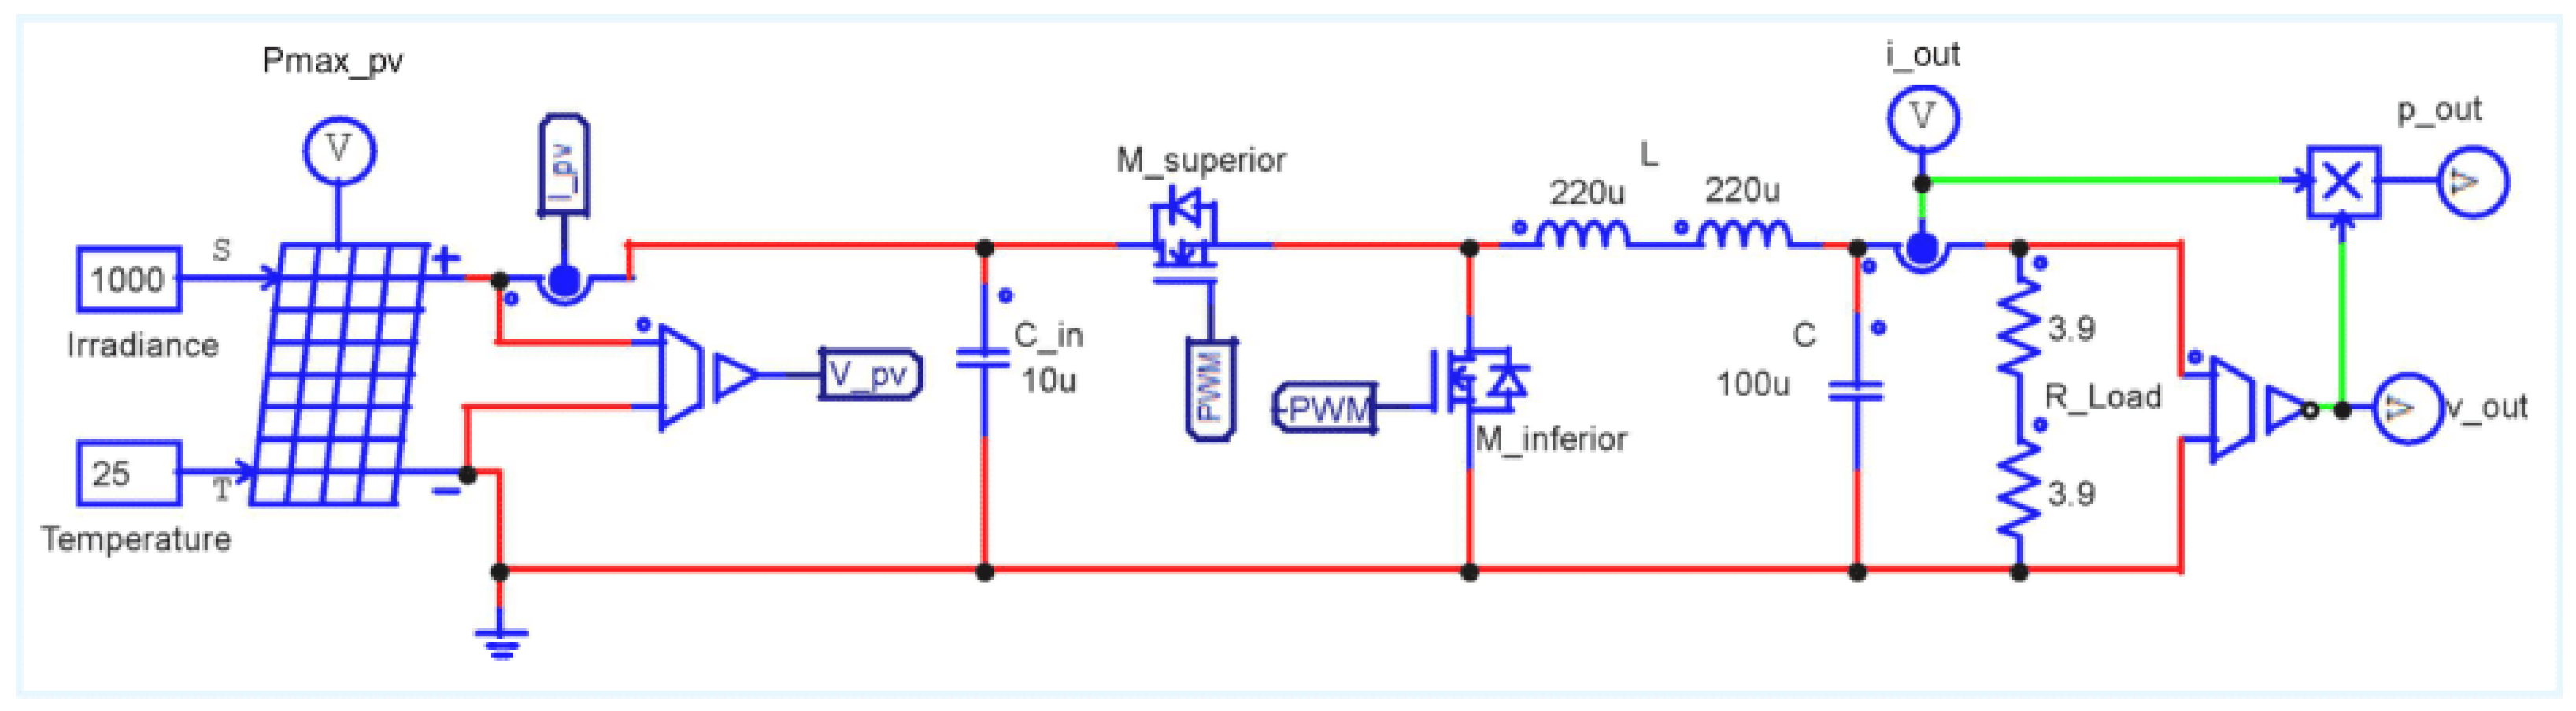
The circuit used in the simulations is illustrated in Figure 15.
Figure 15.
Buck converter implemented in PSIM.
3.2. Conventional P&O
The first algorithm implemented was conventional P&O. Recalling the algorithm’s operating principle, it periodically disturbs the voltage, adjusting the duty cycle, and then evaluates the effect of this change on the power generated by the PV. If the disturbance results in an increase in power, then the next disturbance is applied in the same direction. Otherwise, the disturbance will be applied in the opposite direction, aiming to converge to the MPP. It is important to note that a step of 0.5% was defined in the duty cycle, a value defined after performing some tests.
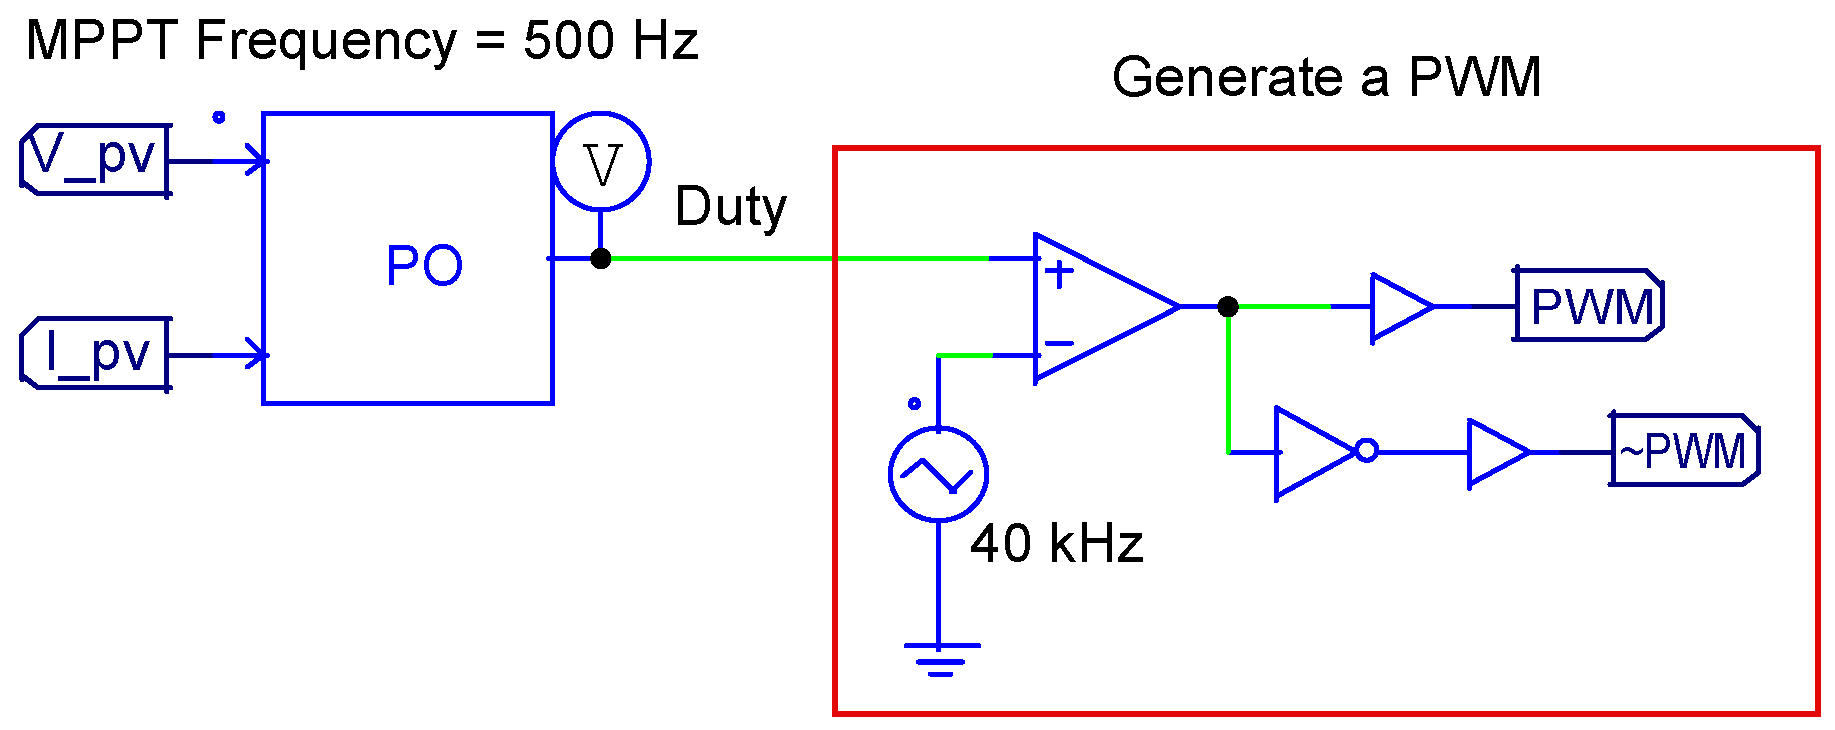
The PSIM “C-Block” (Figure 16) was used, which allows the implementation of code in C language. Before starting the simulation, it was necessary to define the time step, which in this case was set to s. Considering the converter switching frequency of 40 kHz, we obtained
which corresponds to 100 samples per switching cycle, a value considered adequate for a simulation close to reality. In these conditions, the simulation time was 80 s, running on a PC with an Intel(R) Core(TM) i5-10300H CPU @ 2.50 GHz and 8 GB of RAM.
Figure 16.
C-Block in PSIM.
A frequency of 500 Hz was defined for the MPPT, i.e., a disturbance was made in the duty cycle every 2 ms, and the impact of this variation on the extracted power was subsequently evaluated. The frequency used was due to the time required for the converter to stabilize after the duty cycle variation.
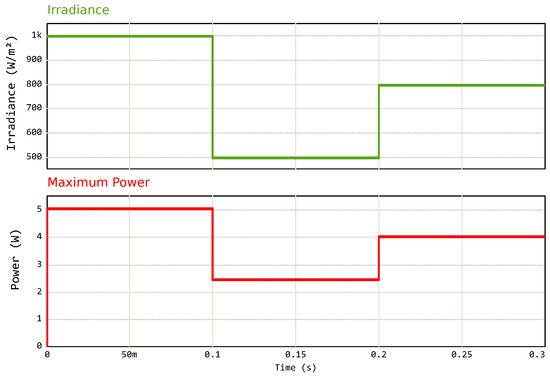
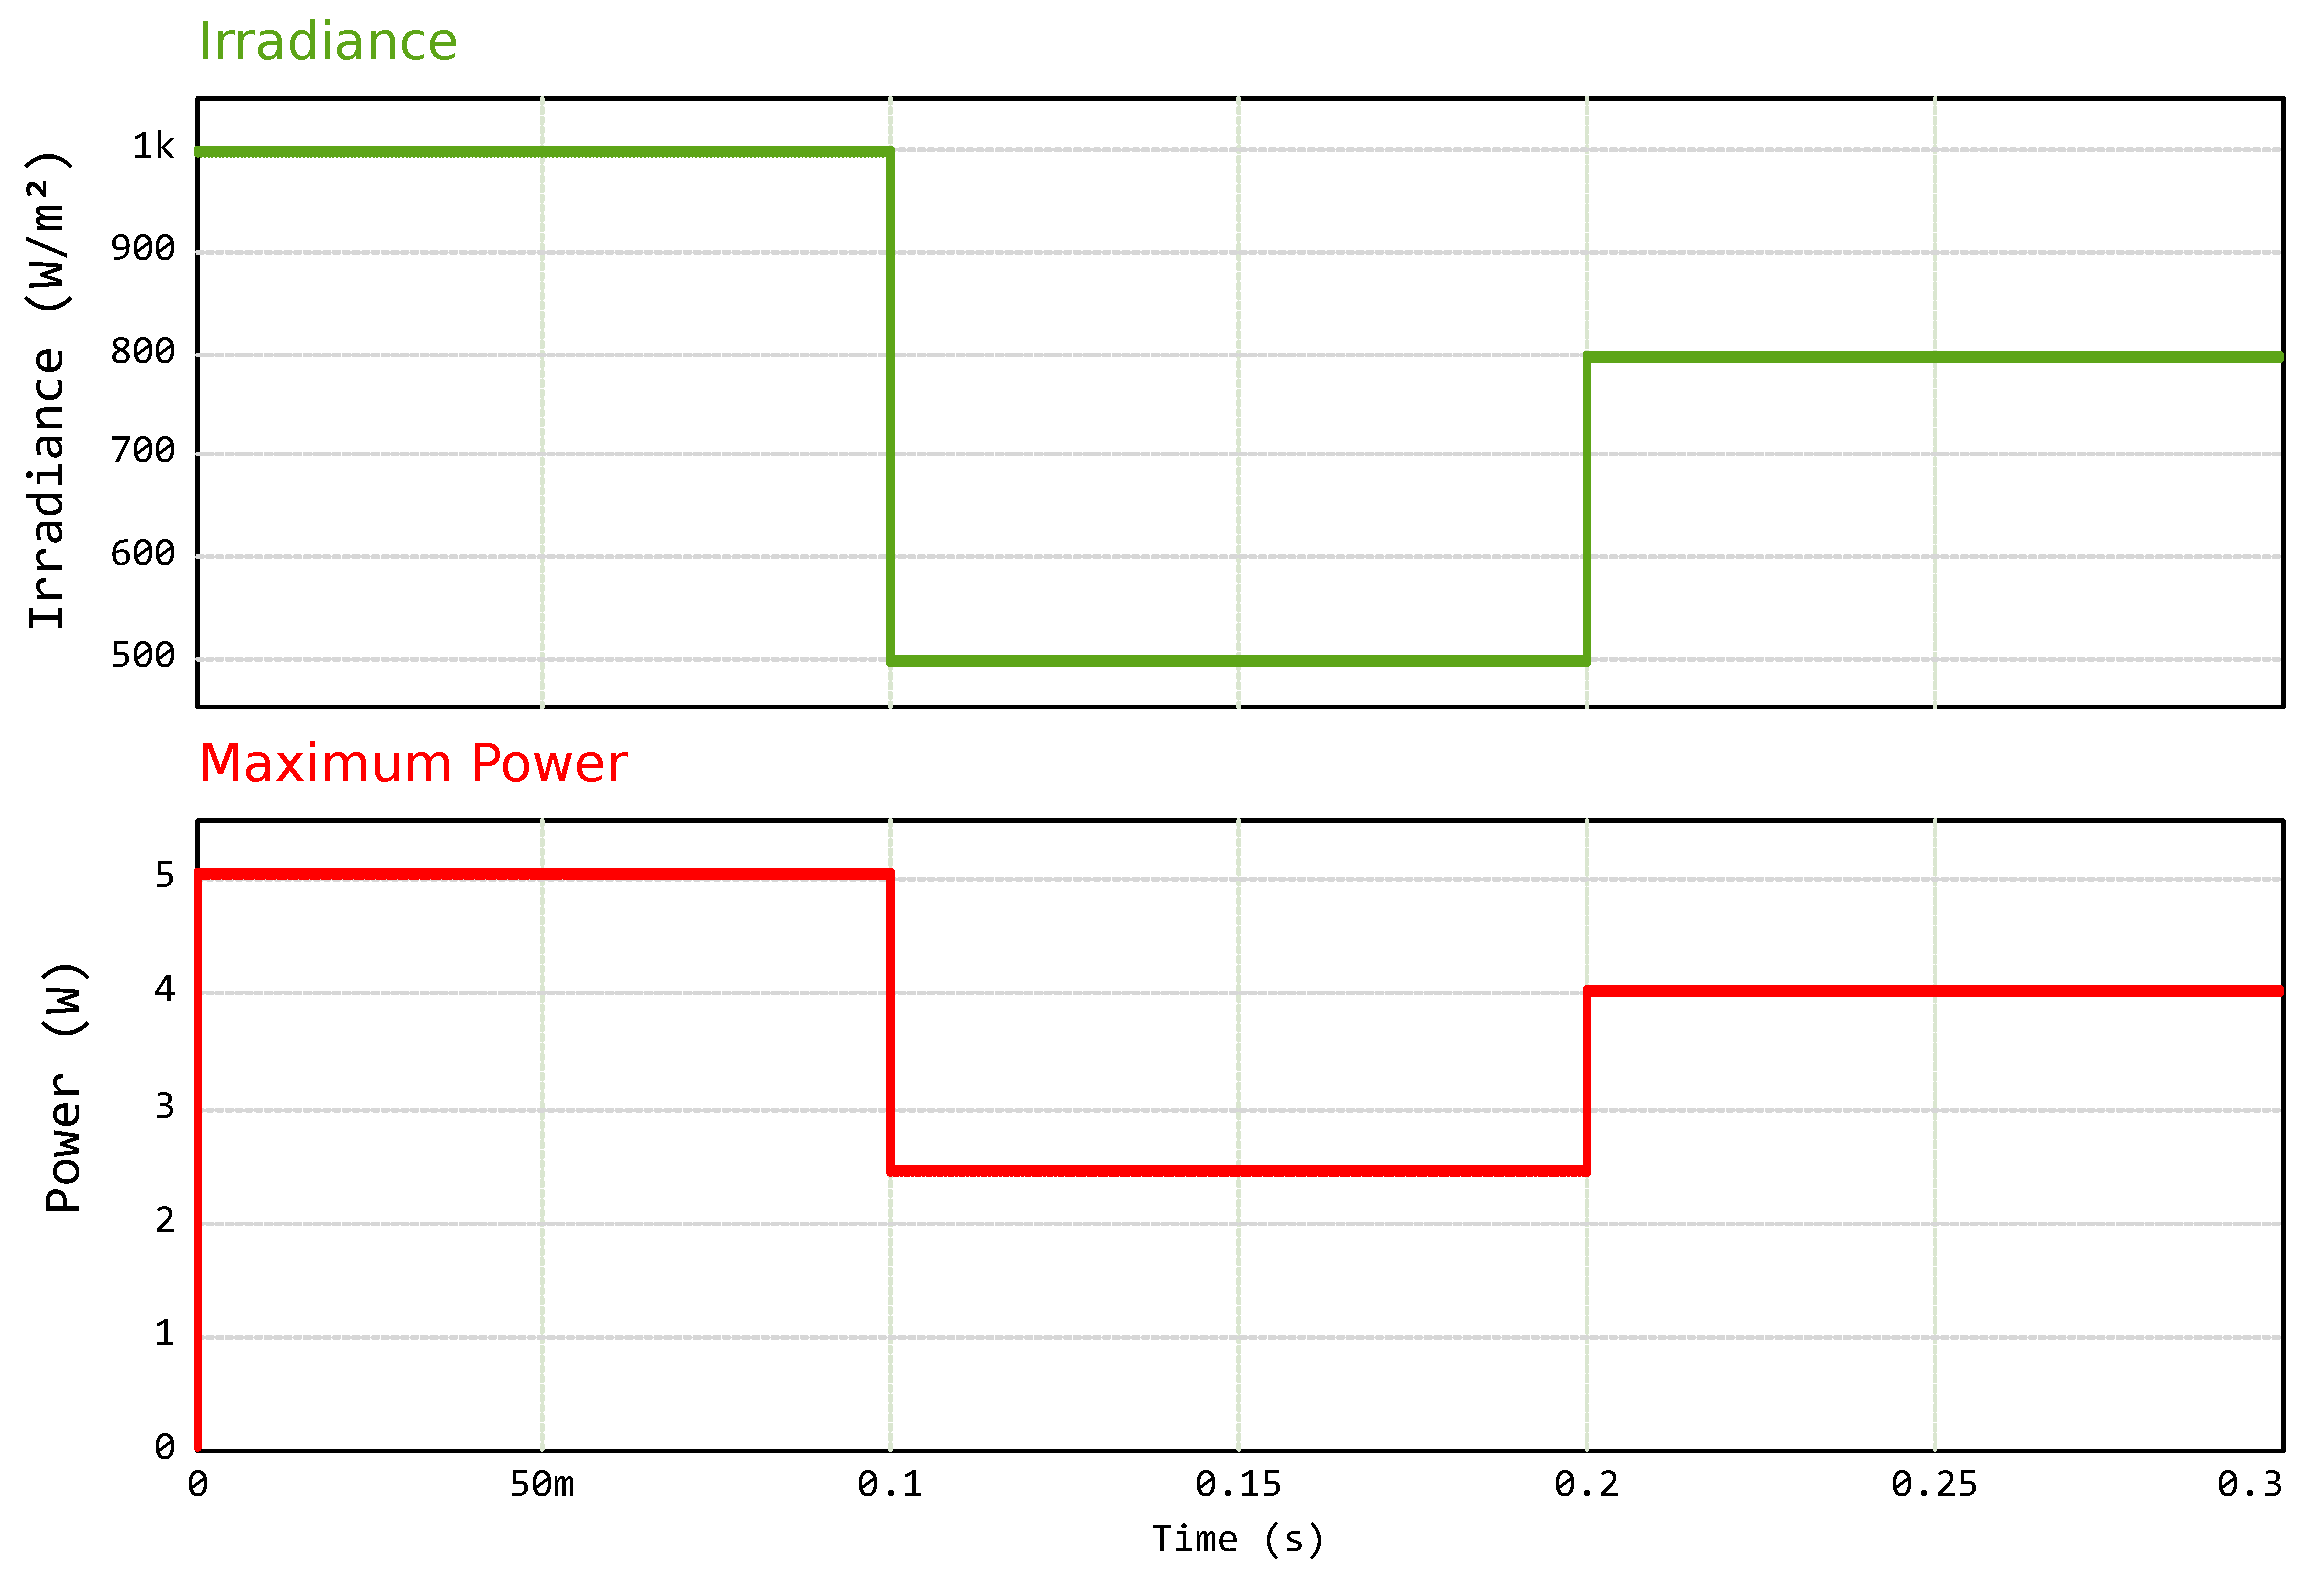
To analyze the performance of the algorithm in the face of variations in climatic conditions, variations in the irradiance level were introduced, as shown in Figure 17. As expected, these changes impacted the maximum power of the photovoltaic system, and this evolution can be observed in the figure itself.
Figure 17.
Variations in irradiance and the corresponding maximum PV power under these conditions.
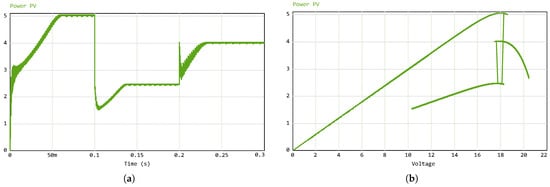
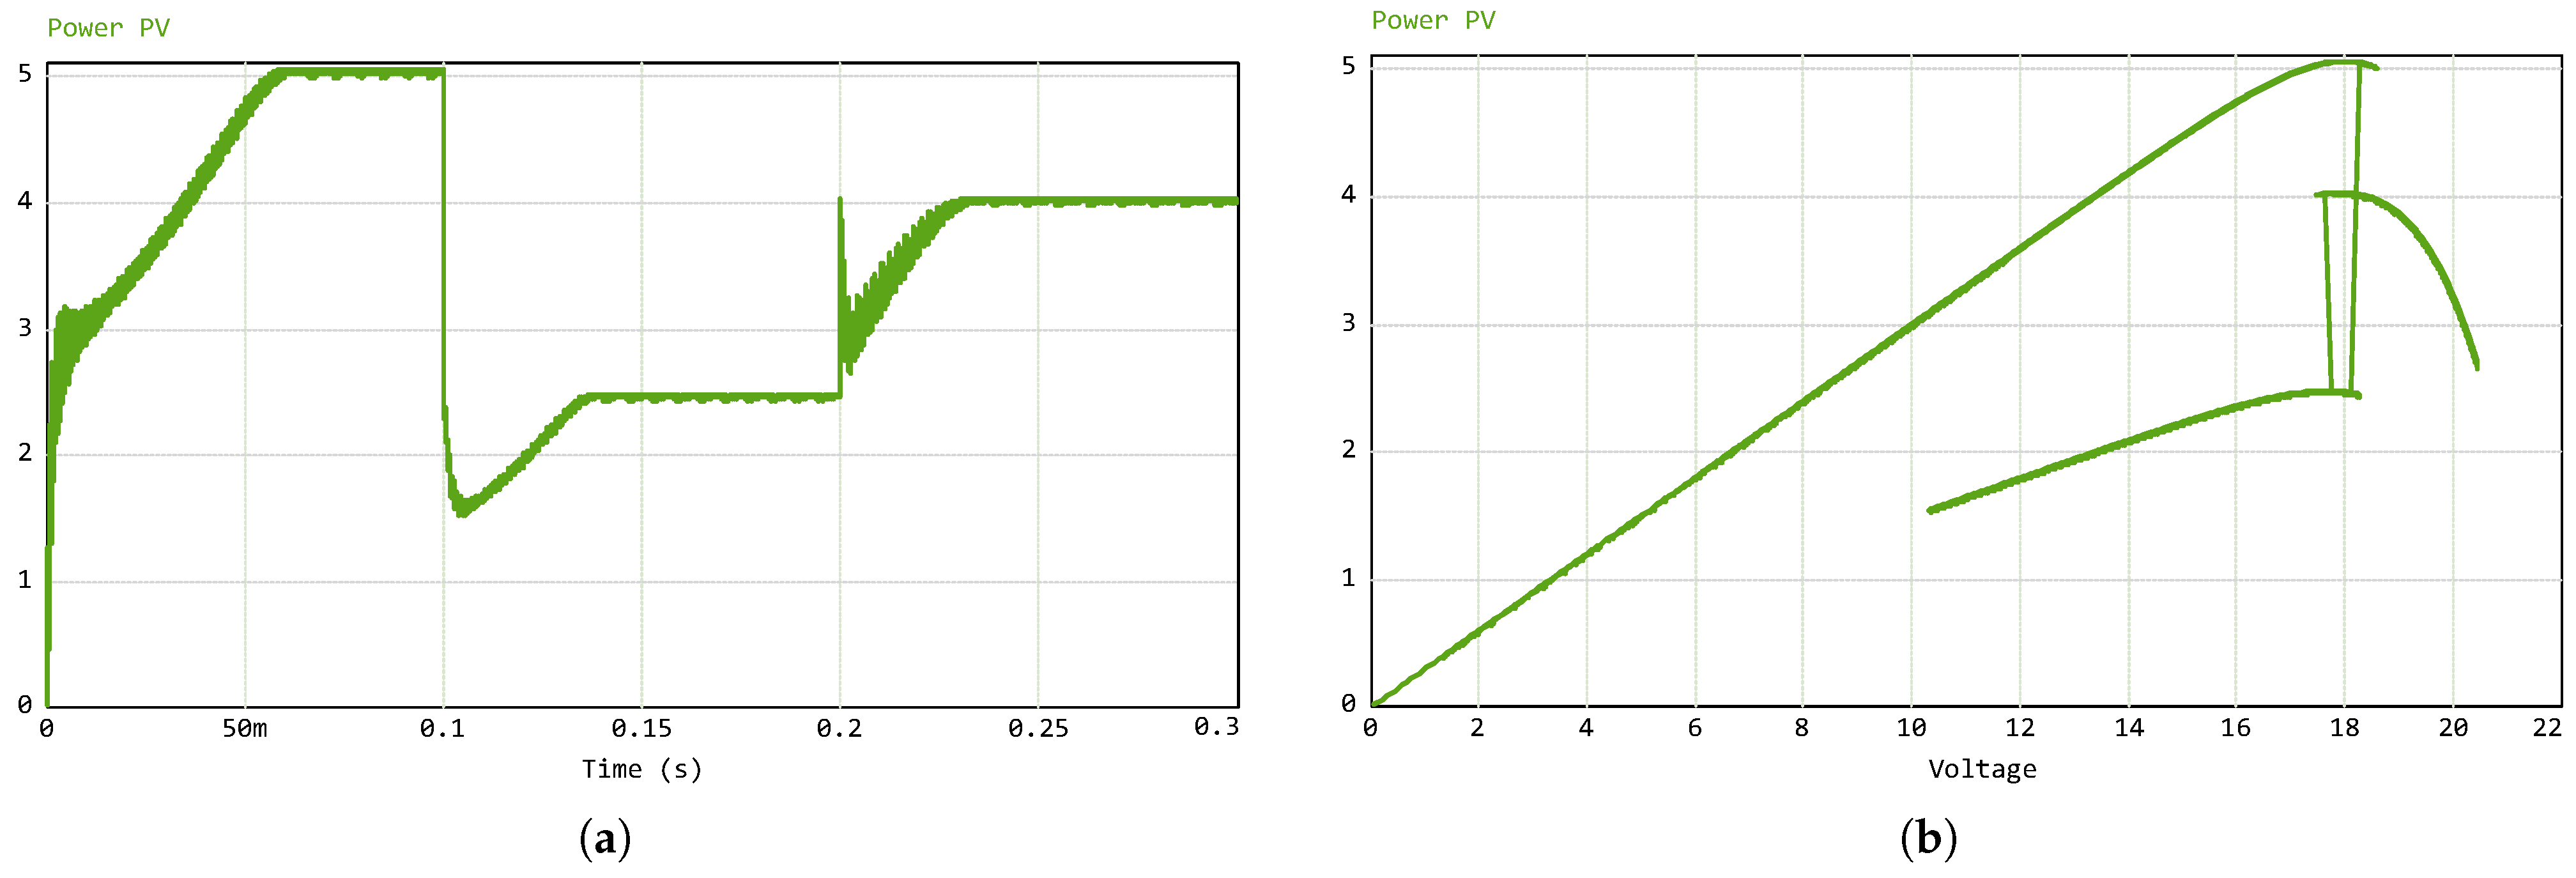
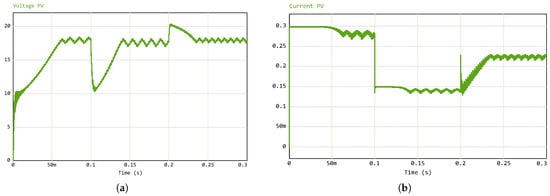
As for the power extracted from the PV, shown in Figure 18a, the algorithm adapted to the applied variations, ensuring that, at each instant, the power obtained remained as close as possible to the maximum value. The algorithm took about 60 ms from the start of MPPT to reach MPP. It can also be observed that although the overall behavior was as expected, oscillations around MPP persisted, being about 54 mW in STCs, a limitation already pointed out for this technique. Table 5 shows the power extracted for each irradiance level. In this table, P&O MPP represents the average power extracted during steady-state operation, and the time required for the algorithm to reach a steady state after each change in irradiance is also indicated. Figure 18b shows the P-V curve corresponding to these variations, demonstrating that the algorithm maximized the power by adjusting the voltage, as expected. Figure 19a and Figure 19b show the evolution of voltage and current over time, respectively. The oscillations in a steady state are noteworthy.
Figure 18.
Power curves for the implemented P&O: (a) P(t) curve and (b) P-V curve.
Table 5.
Power extracted for each irradiance level of the P&O algorithm.
Figure 19.
Variation in (a) voltage and (b) current for the conventional P&O algorithm.
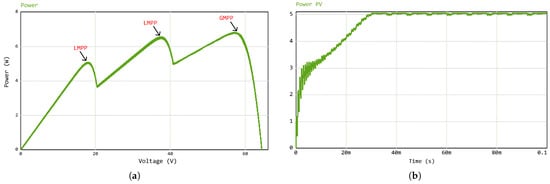
One of the obvious disadvantages of this technique is its response under PSCs. Under these conditions, multiple maximum power points arise, which can cause the algorithm to converge to an LMPP without ensuring that the GMPP is reached. To analyze the behavior under PSCs, three panels in series were used under the conditions shown in Figure 13b. Recalling the P-V curve under PSCs (Figure 20a), the GMPP was close to 7 W. The P(t) curve illustrated in Figure 20b confirms the P&O limitation, showing that the algorithm remained “stuck” at the LMPP (around 5 W) without reaching the GMPP.
Figure 20.
(a) P-V curve and (b) P&O response for PSCs.
3.3. GTO
The next algorithm implemented was the GTO, in which each “gorilla” corresponds to a value assigned to the duty cycle. In practical terms, this value is applied directly to the converter, with a sufficient period expected for the dynamic response of the system to stabilize. After this period, the impact of the individual on the extracted power is evaluated. However, this procedure implies an increase in tracking time, as it involves the actual physical evaluation of the system. In this type of approach, replacing this step with an equivalent mathematical model would enable significantly faster tracking, since it would not be necessary to wait for the stabilization time.
For initial comparison purposes, the most common values found in the literature were adopted for the W, and p parameters, defined as 0.8, 3 and 0.03, respectively. Once the number of iterations has been reached, the converter starts operating with the duty cycle value considered optimal, i.e., that associated with the silverback. However, the algorithm was structured to perform a new search for the best solution after a defined interval. In the tests performed, this update was configured to occur every 0.6 s, with the aim of reducing the total simulation time. In real contexts, given that such sudden changes in weather conditions are not expected, a longer time interval for this new search would be more appropriate.
The initial population was generated randomly, consisting of six gorillas with duty cycle values ranging between the established limits, specifically between 5% and 95%. With the population formed, everyone was evaluated to identify the silverback. The time defined for the converter to reach stabilization before evaluation was 7.5 ms, a value determined from preliminary tests. Once the initial population assessment has been completed, the exploration phase begins, in which the formulas presented in Equation (1) are applied.
Once the evaluation of all individuals in the previous stage is complete, the exploitation phase begins. Based on the formulas presented in Section 2.2.2, to generate the values corresponding to N1 and N2, the Box–Muller transform method was used, which allows the creation of random variables with normal distribution using Equations (16) and (17) [31,32]:
In these equations, and are random numbers uniformly distributed in the interval [0, 1]. The evaluation of this new population follows the same guidelines applied in the previous phase.
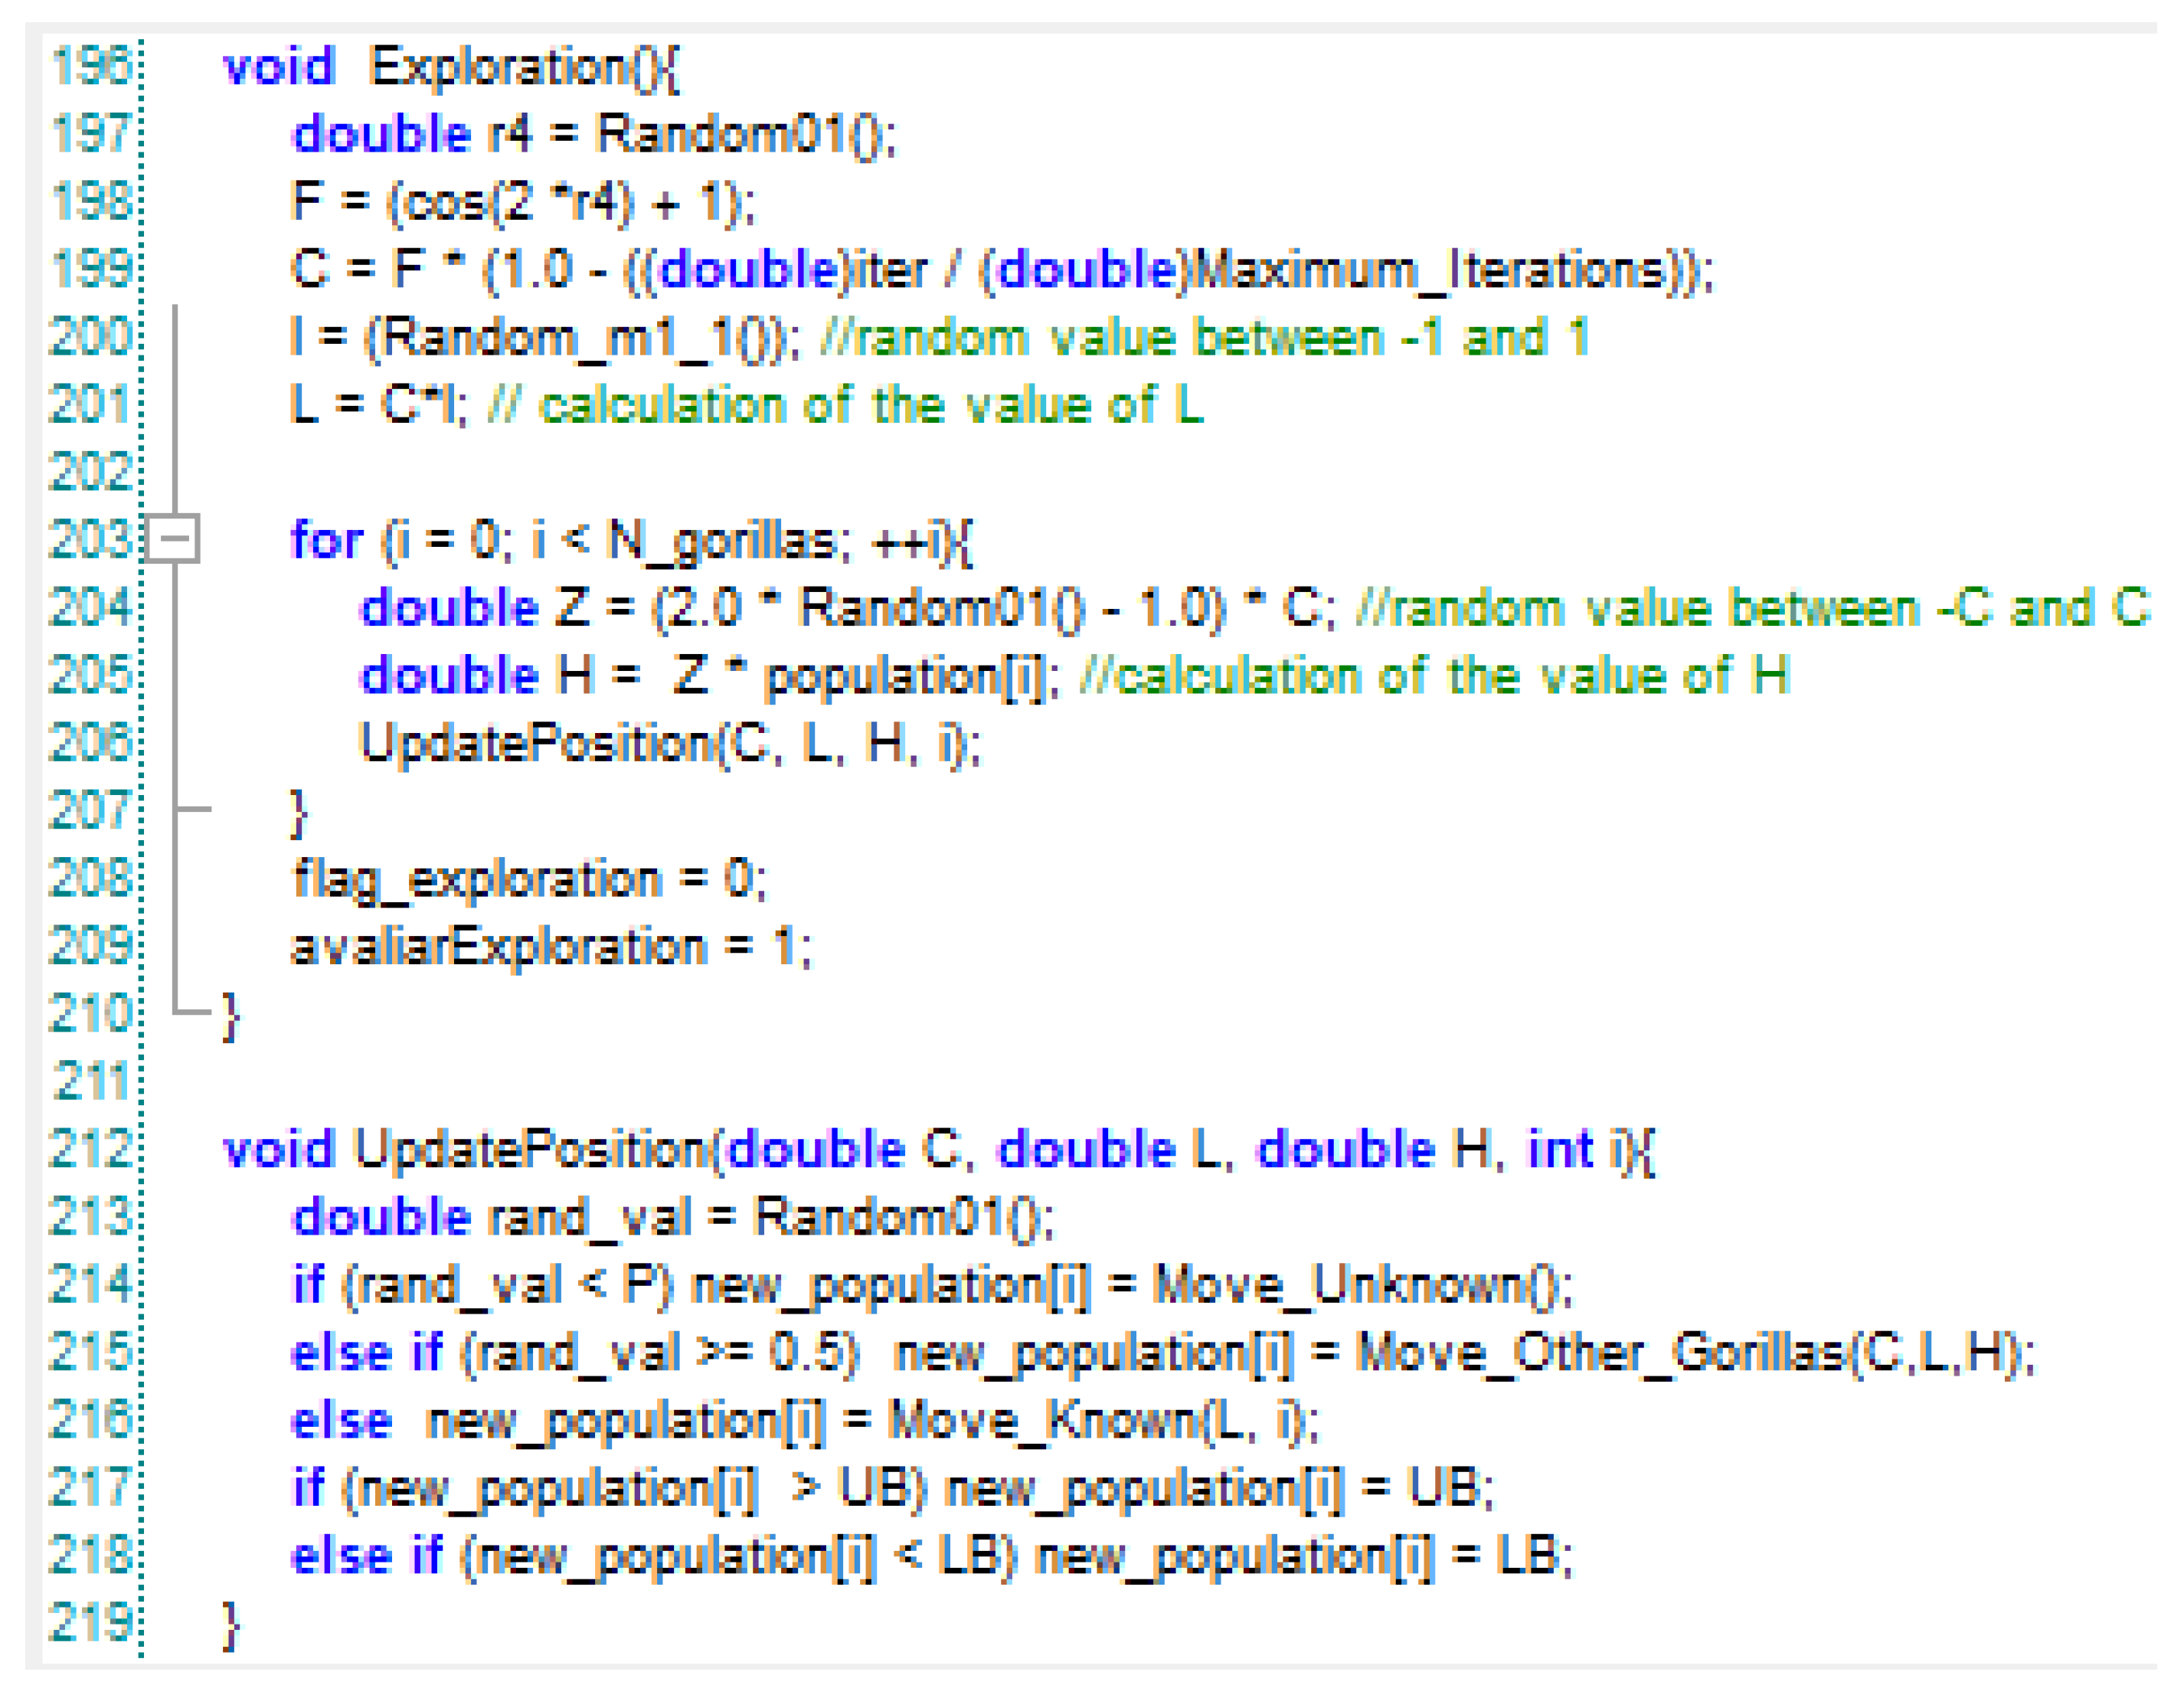
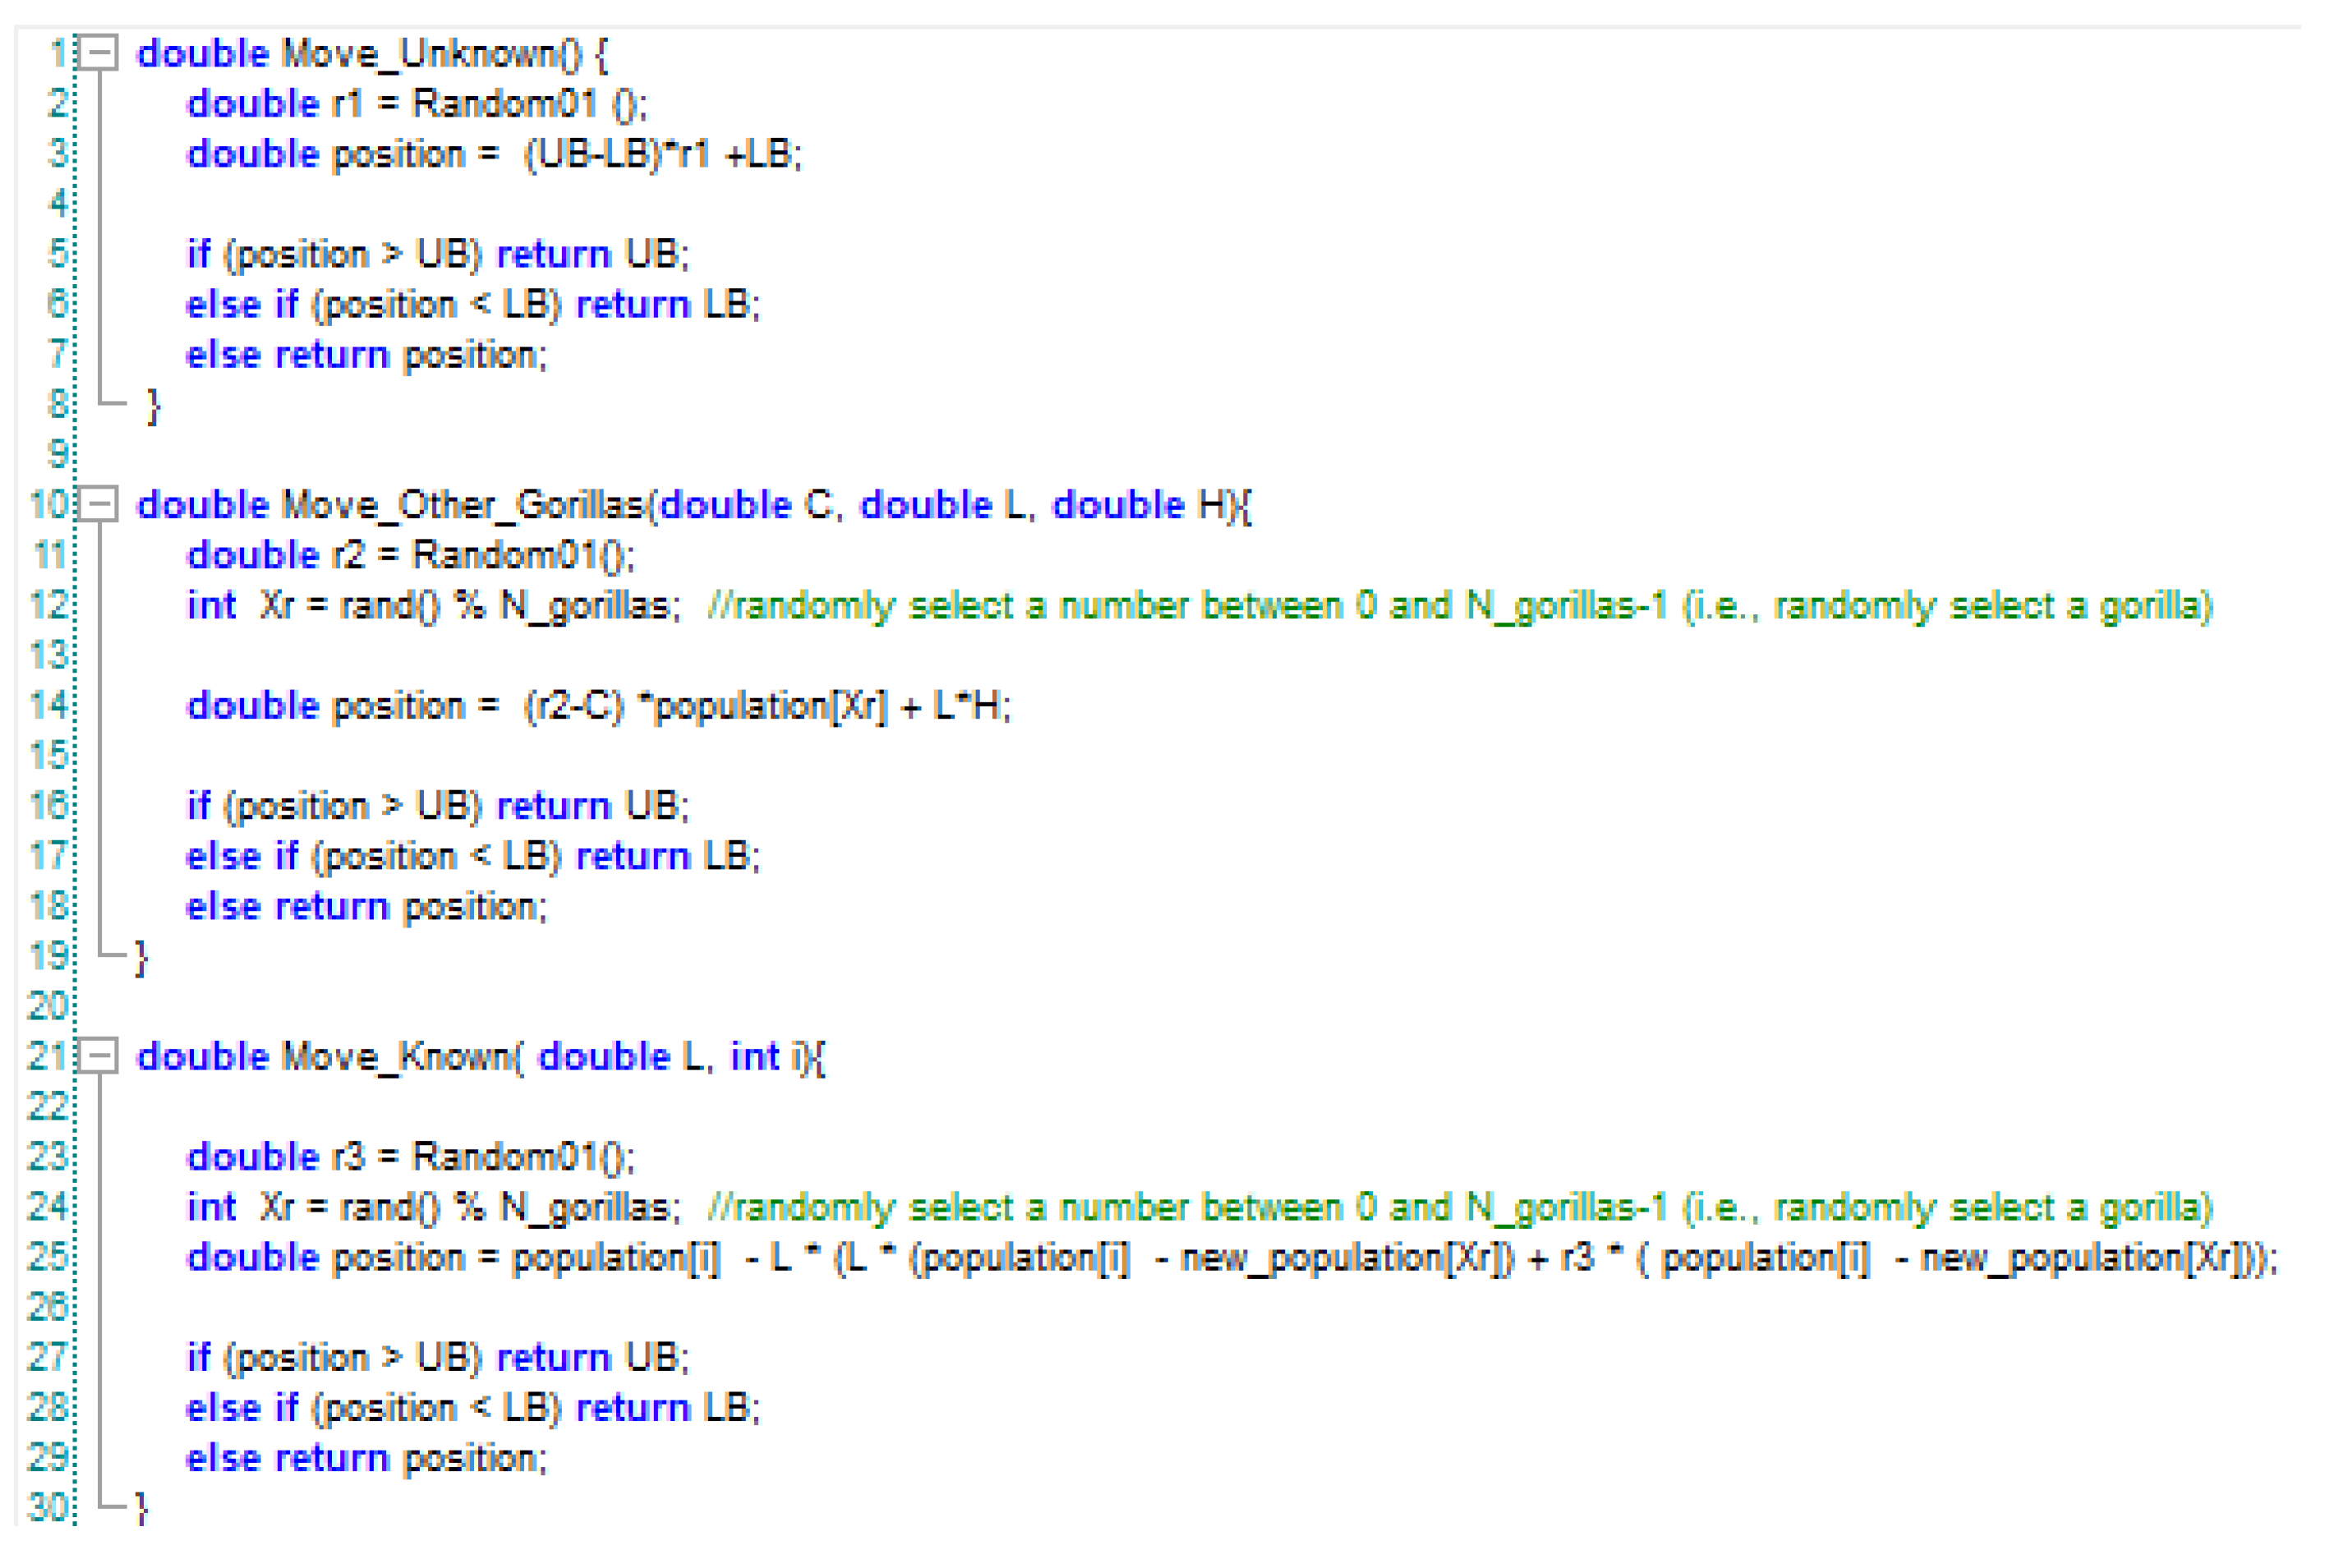
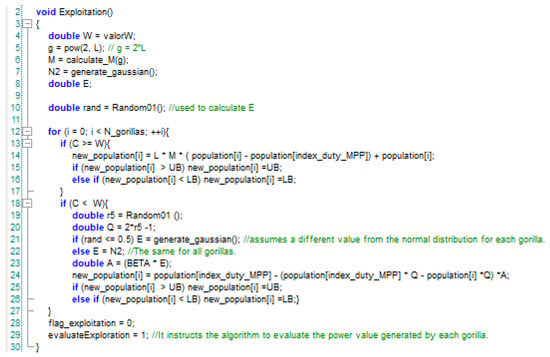
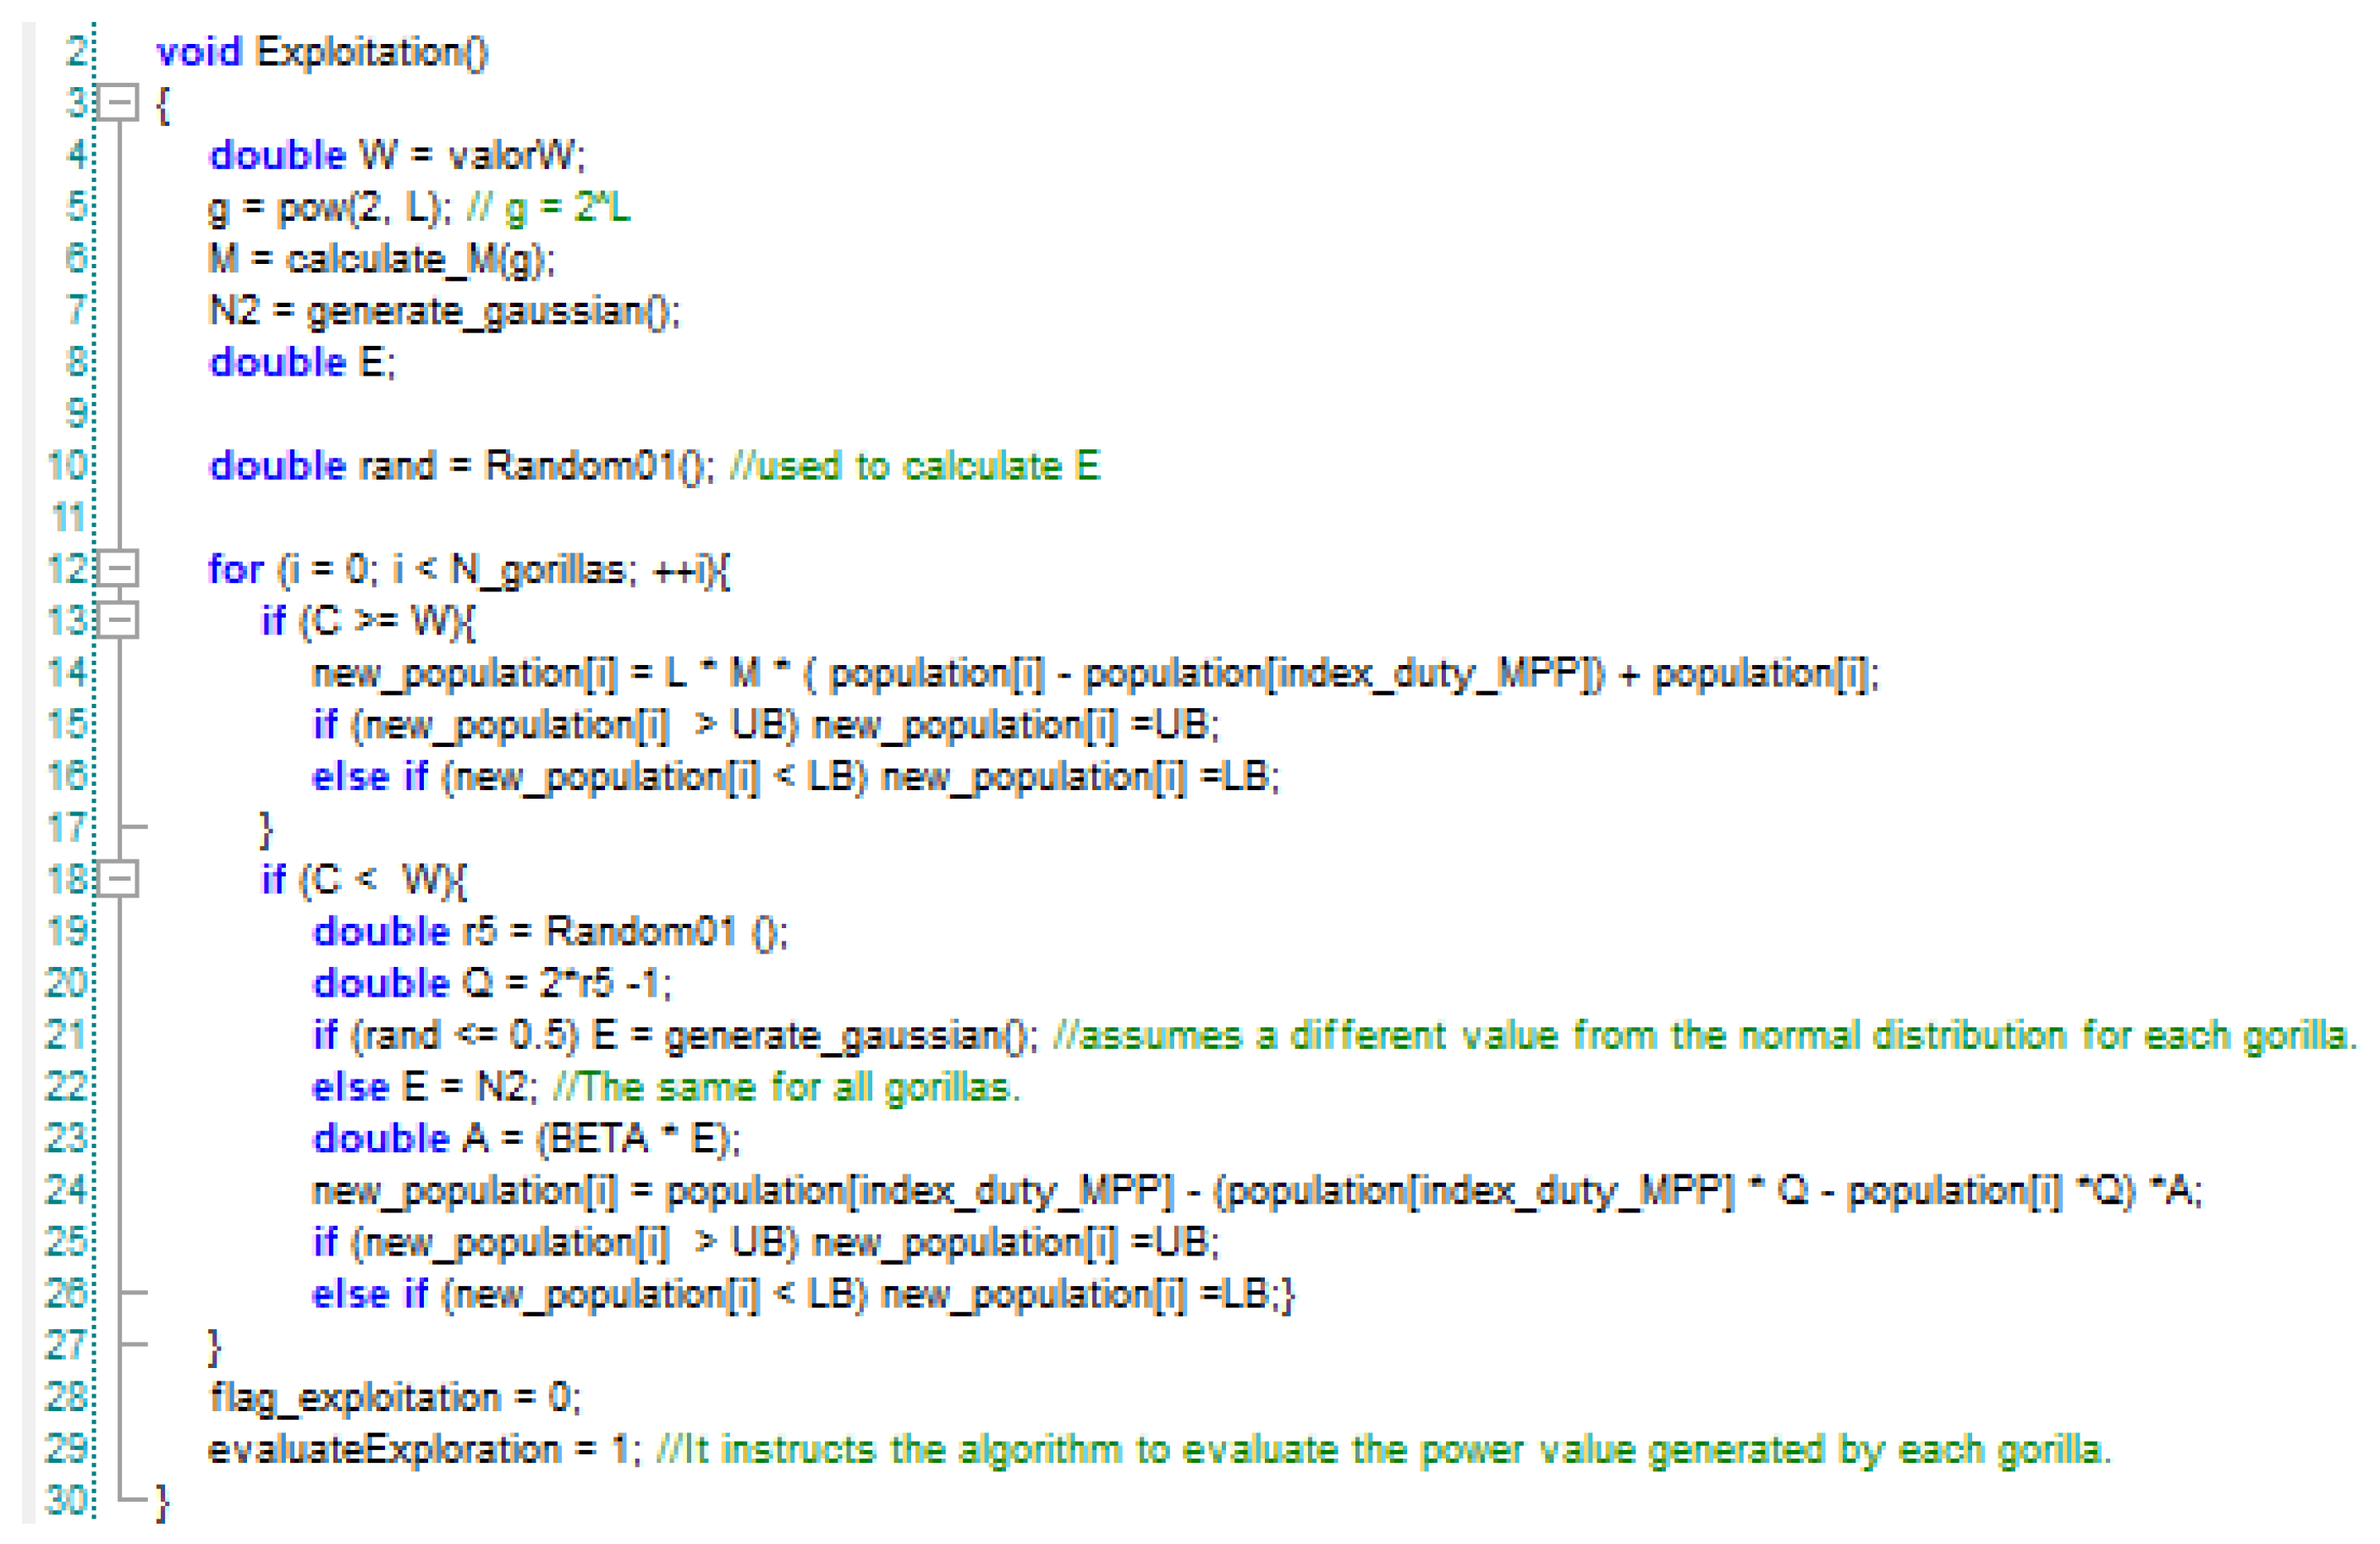
The following figures illustrate the details of GTO implementation using the PSIM C-Block. Figure 21 illustrates the implementation of the exploration phase, and Figure 22 shows the corresponding movements. Figure 23 illustrates the implementation of the exploitation phase.
Figure 21.
C-Block implementation of exploration phase.
Figure 22.
C-Block implementation of exploration movements.
Figure 23.
C-Block implementation of exploitation phase.
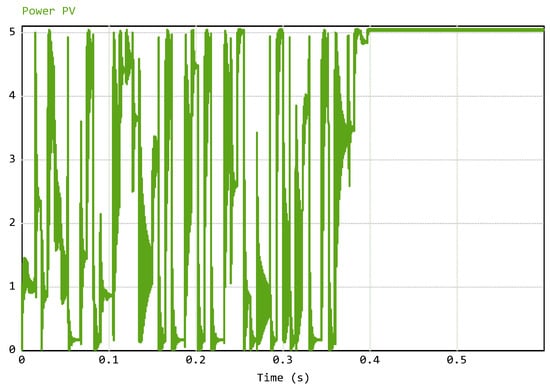
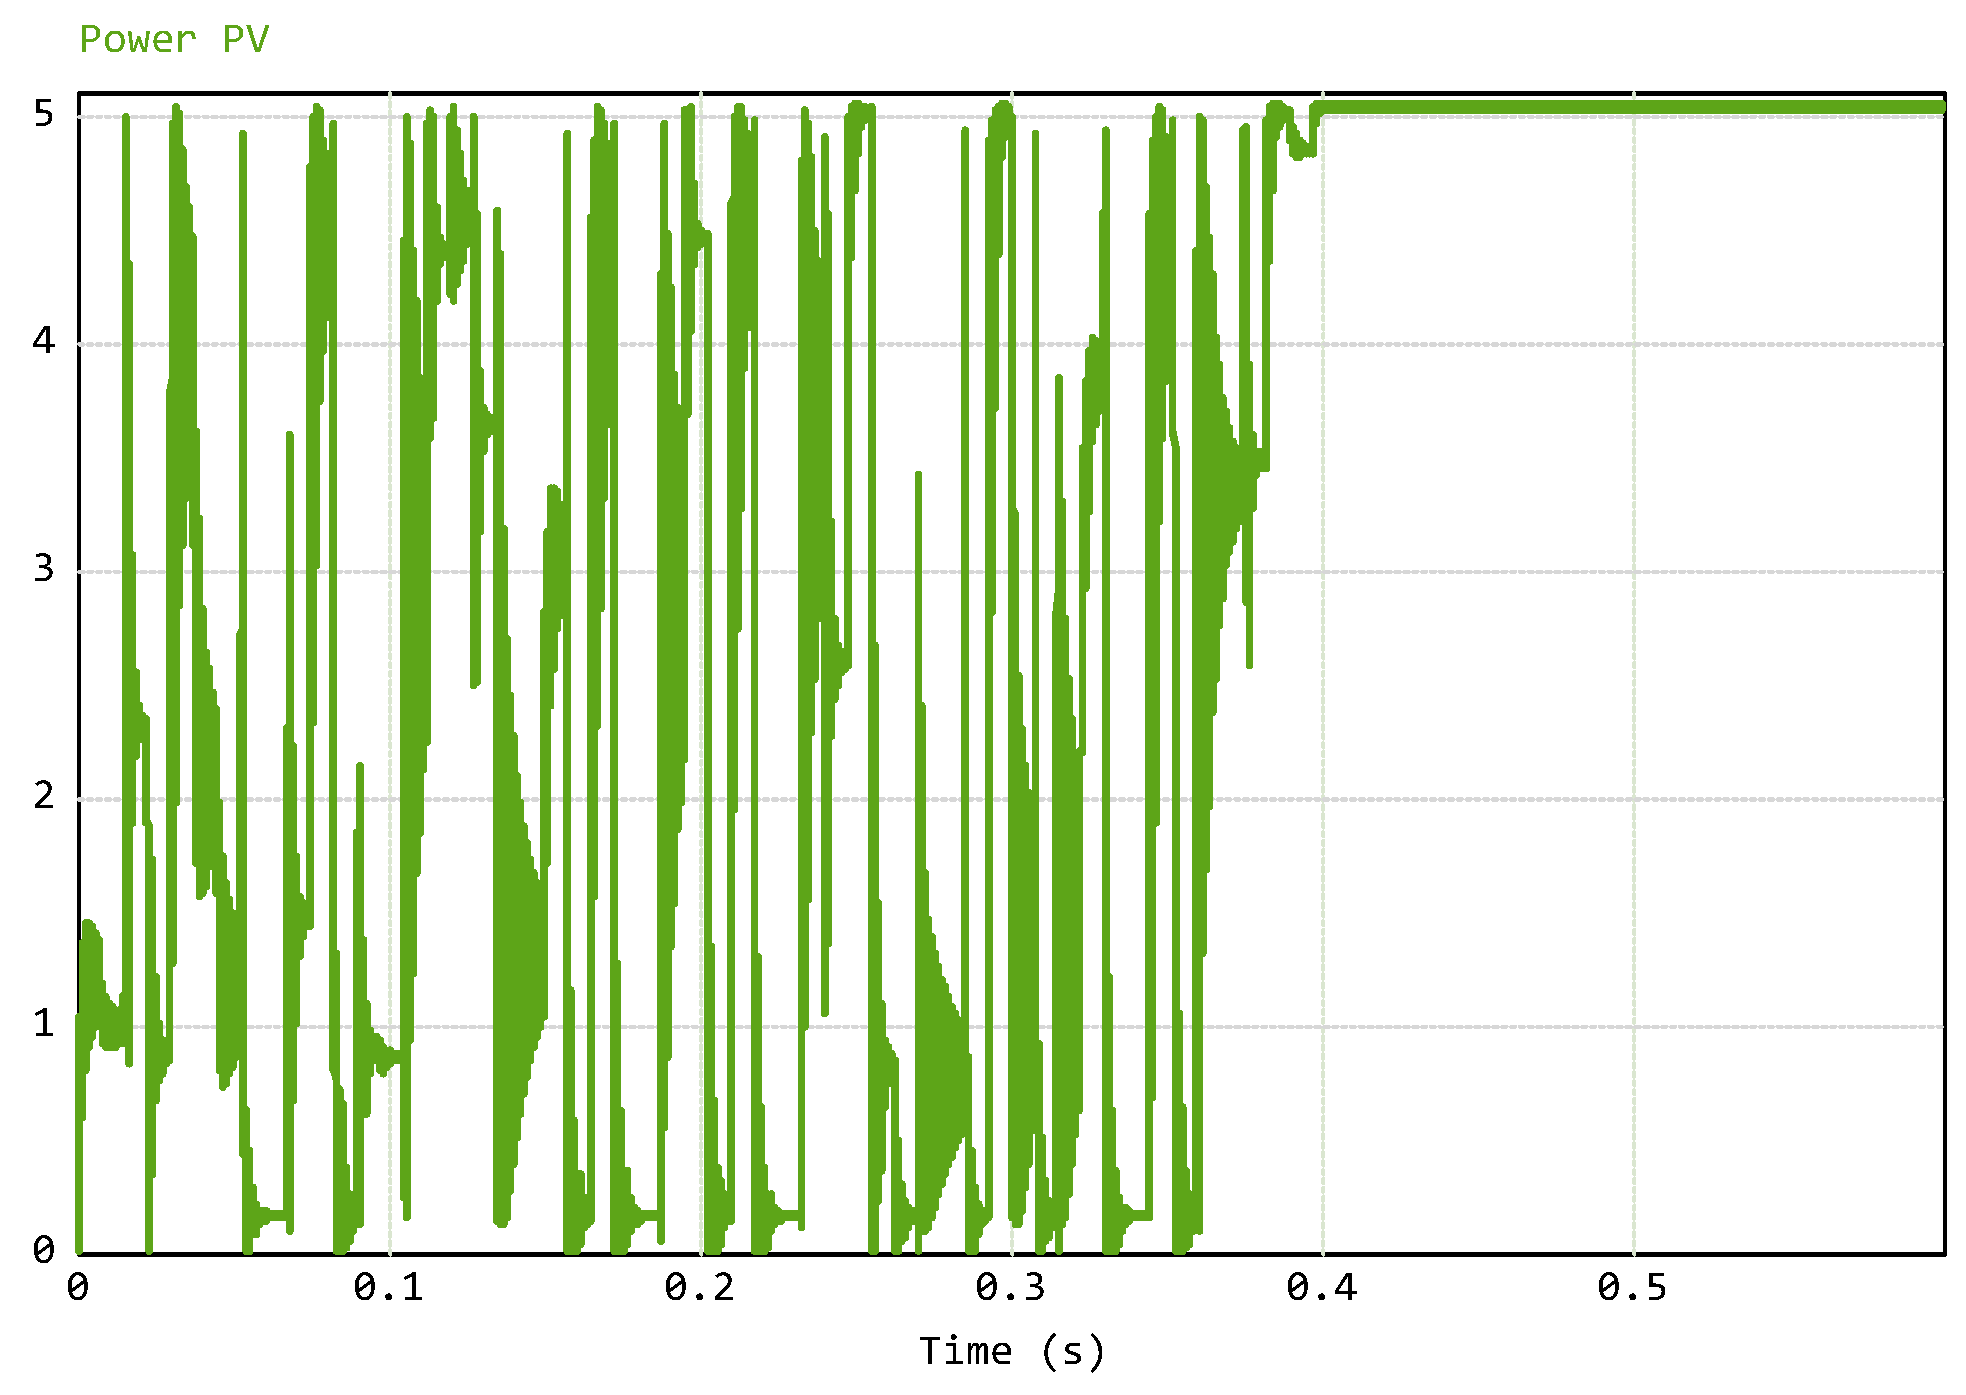
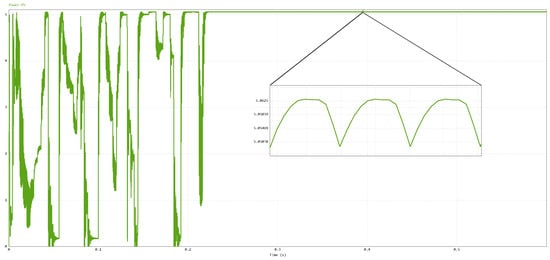
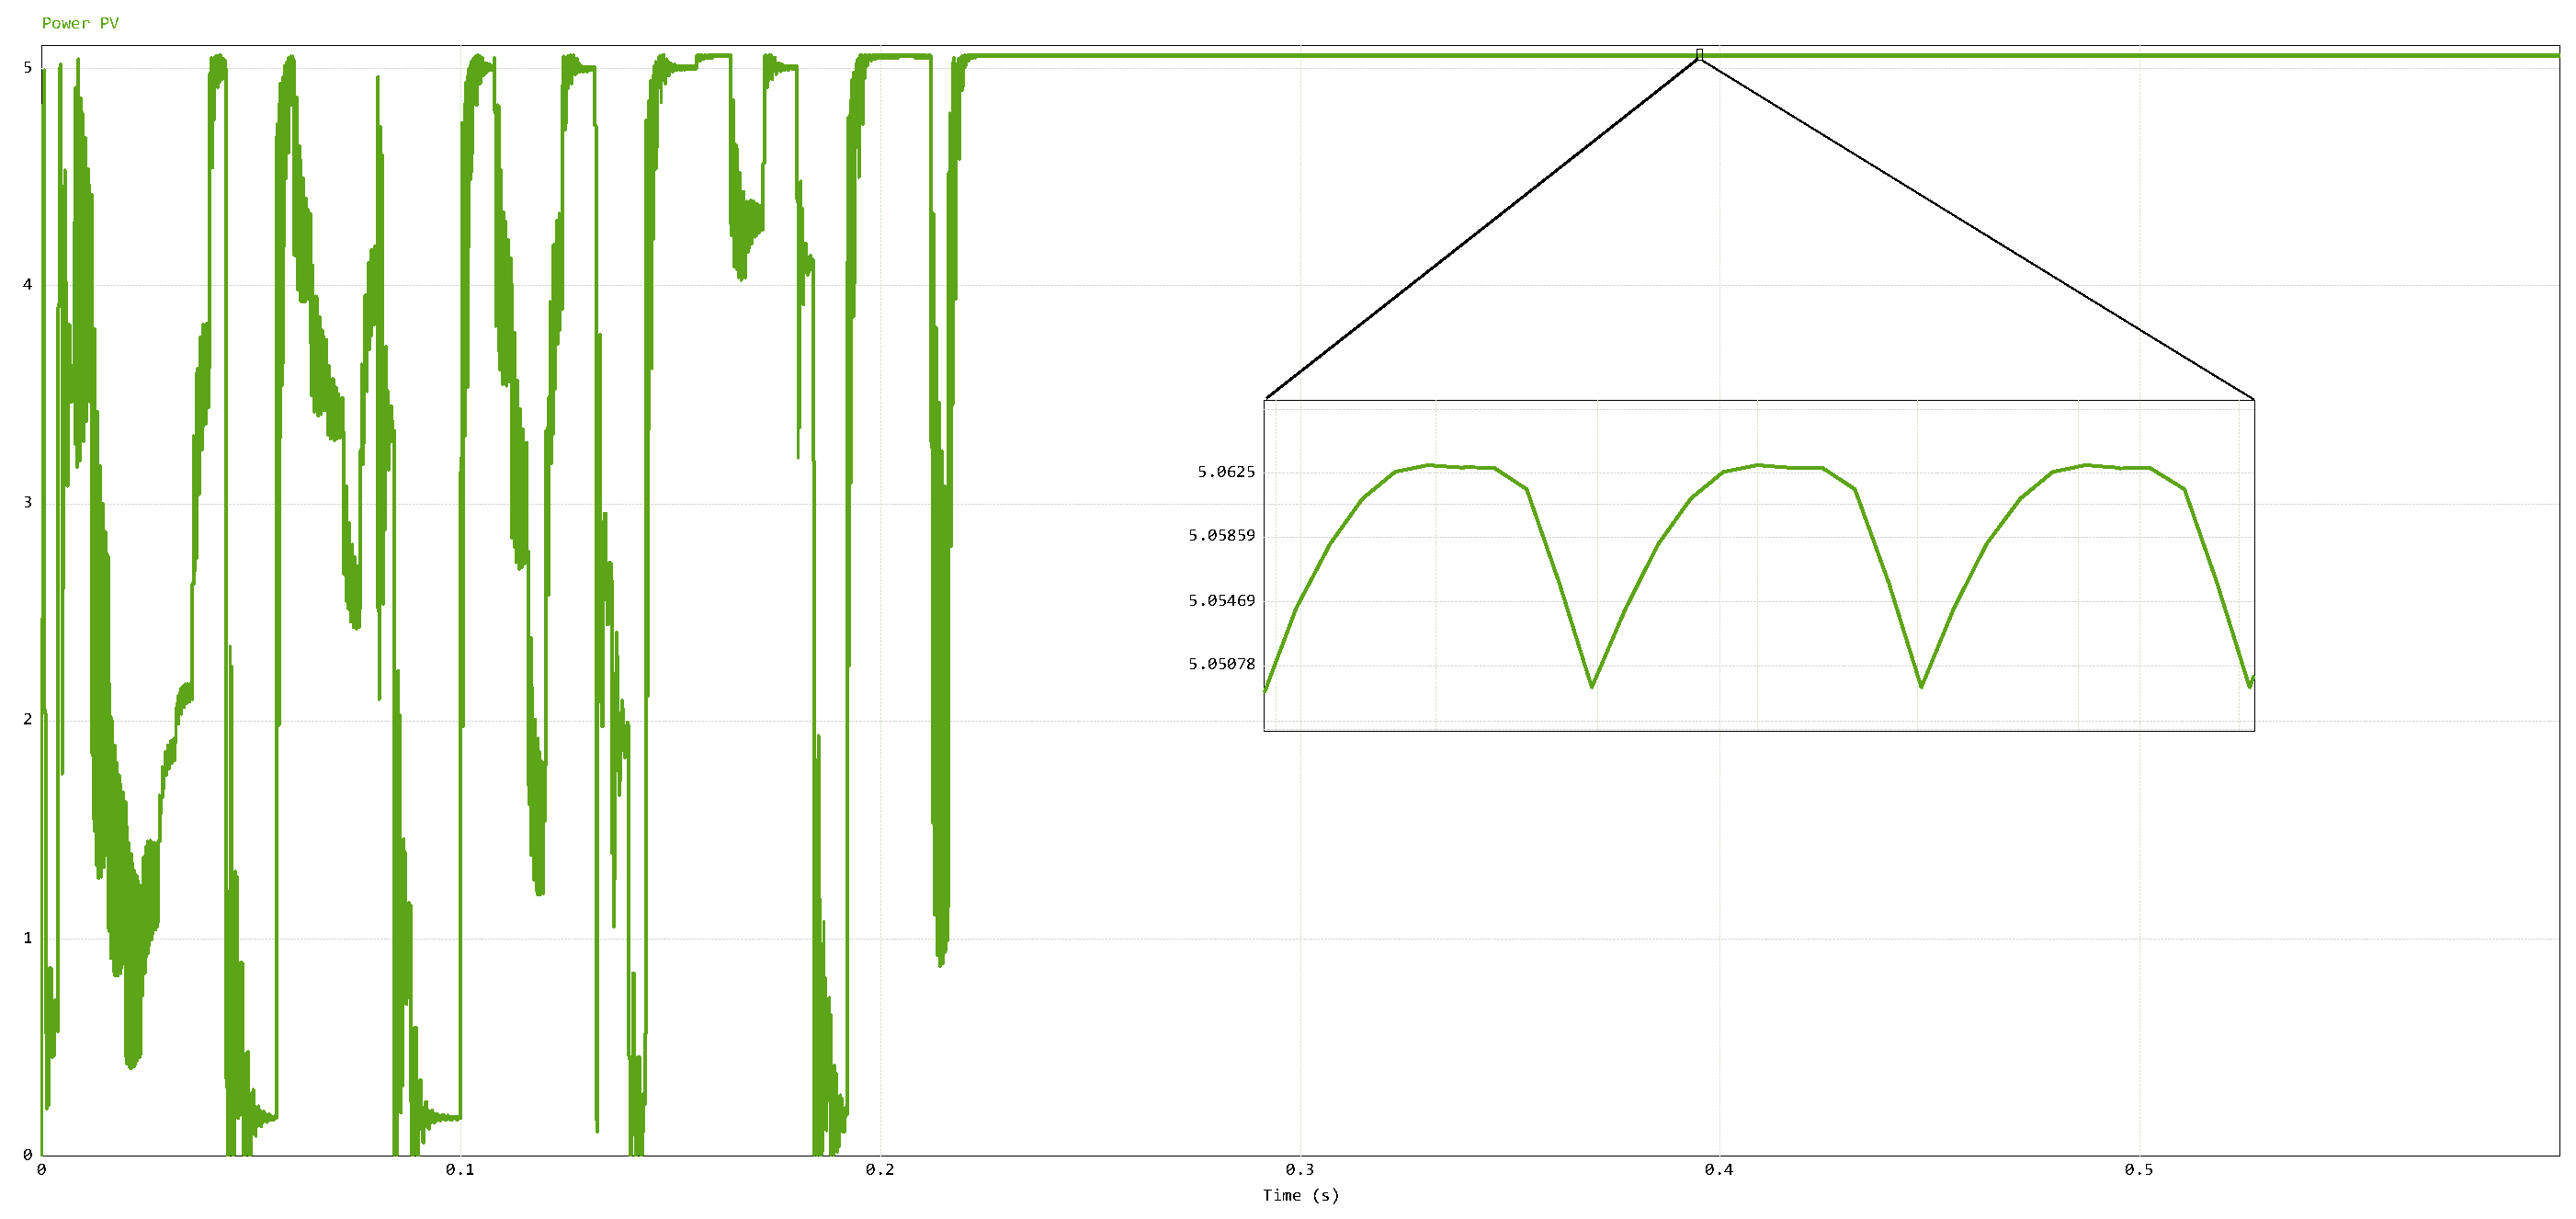
The algorithm tests were initially performed by simulating STCs. Figure 24 shows the evolution of the power extracted from the photovoltaic system over time. The maximum power obtained under these conditions was 5.056 W, with smaller oscillations than in the previous algorithm, being to the order of 21 mW in a steady state.
Figure 24.
Power curve for traditional GTO under STCs.
The time required for the system to reach a steady state can be determined by Equation (18), in which the first term corresponds to the evaluation of the initial population while the second is multiplied by two due to the existence of two distinct phases (exploration and exploitation). Thus, the significant impact of the stabilization time on the algorithm’s convergence process can be seen:
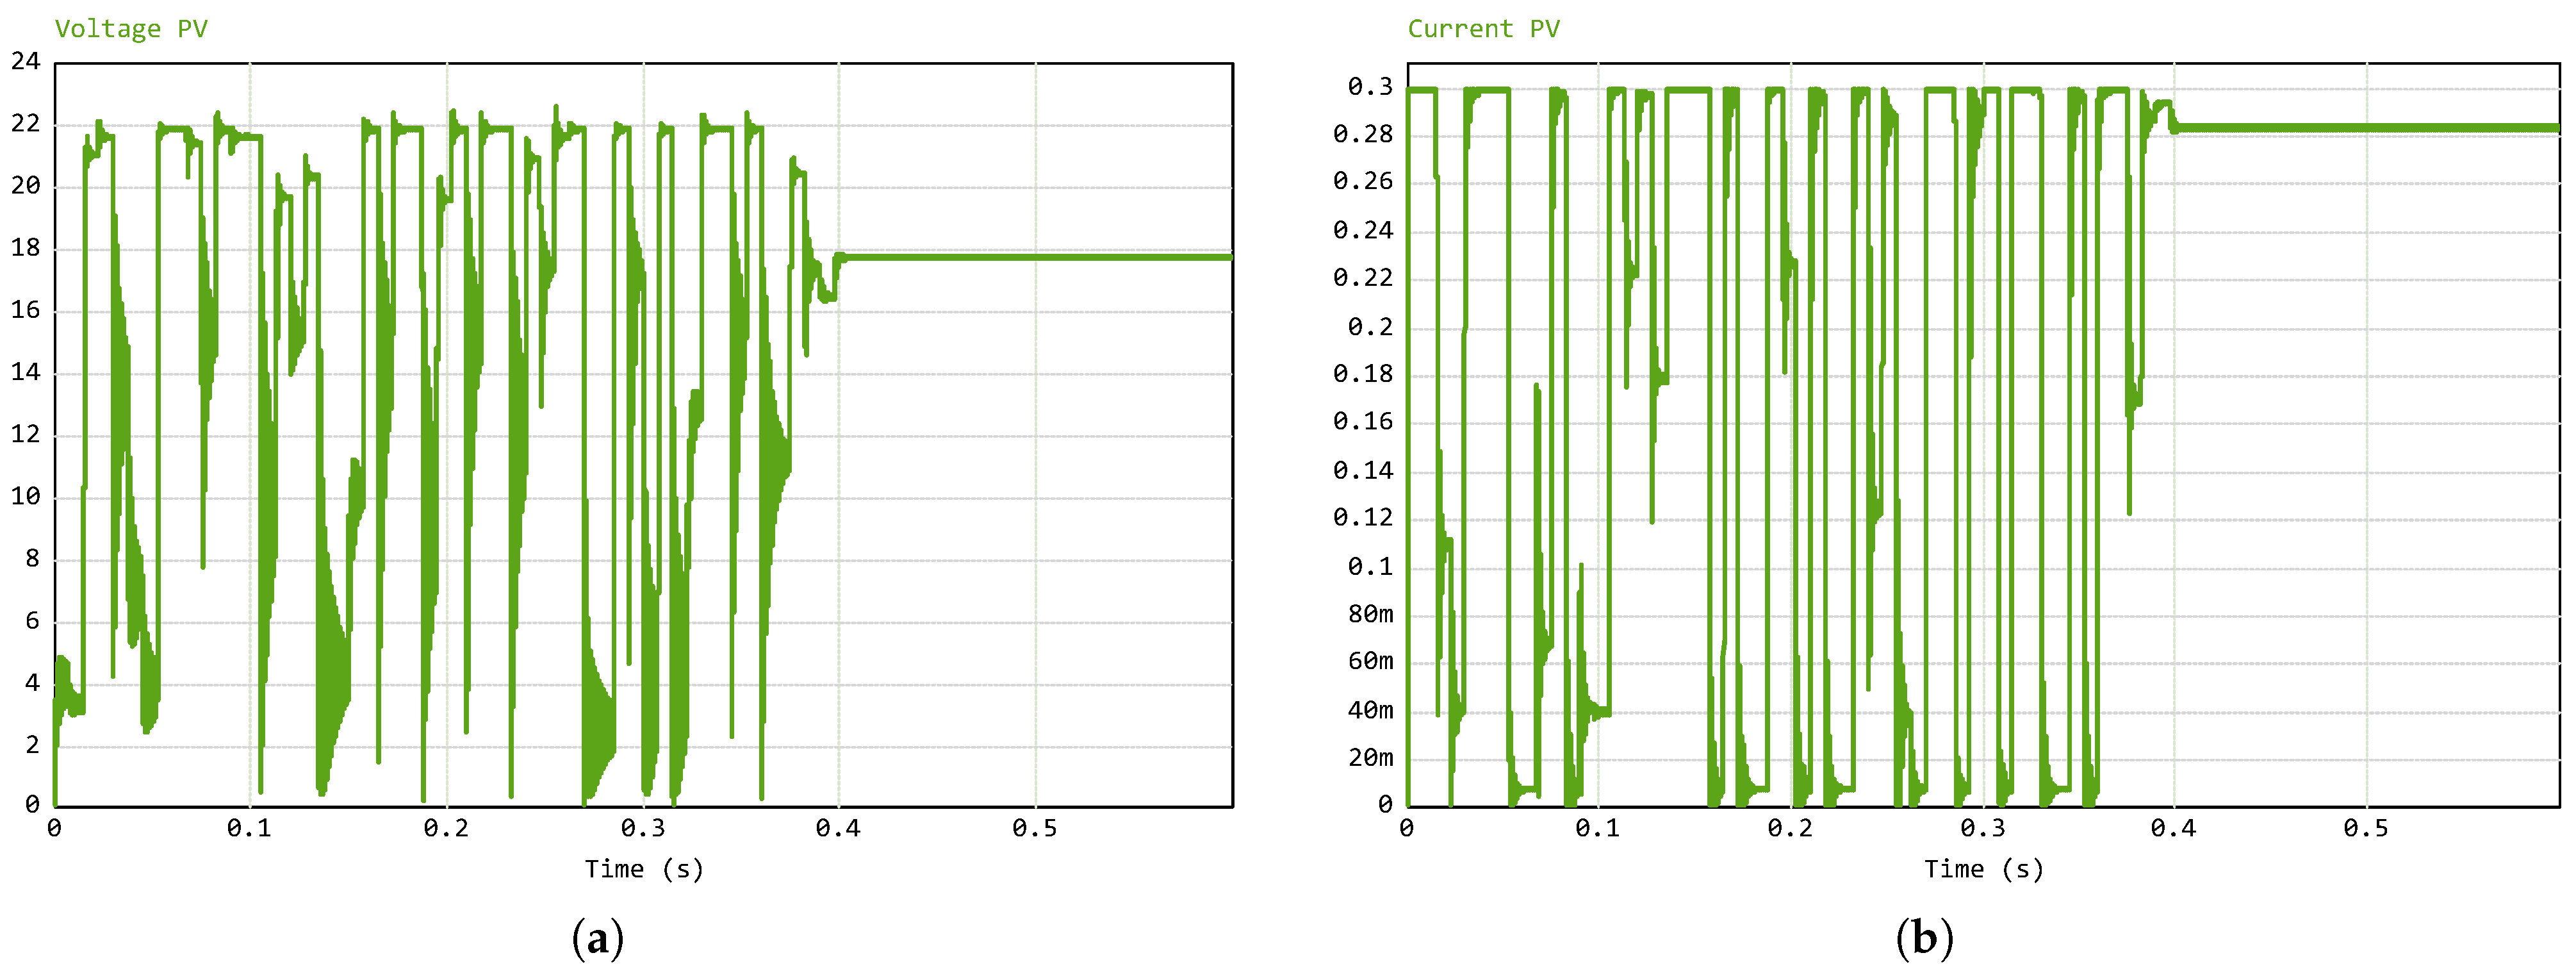
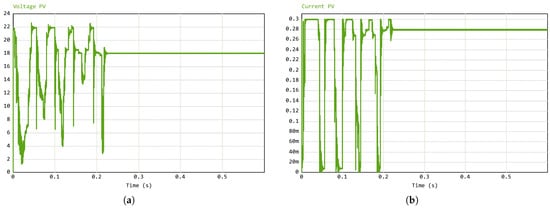
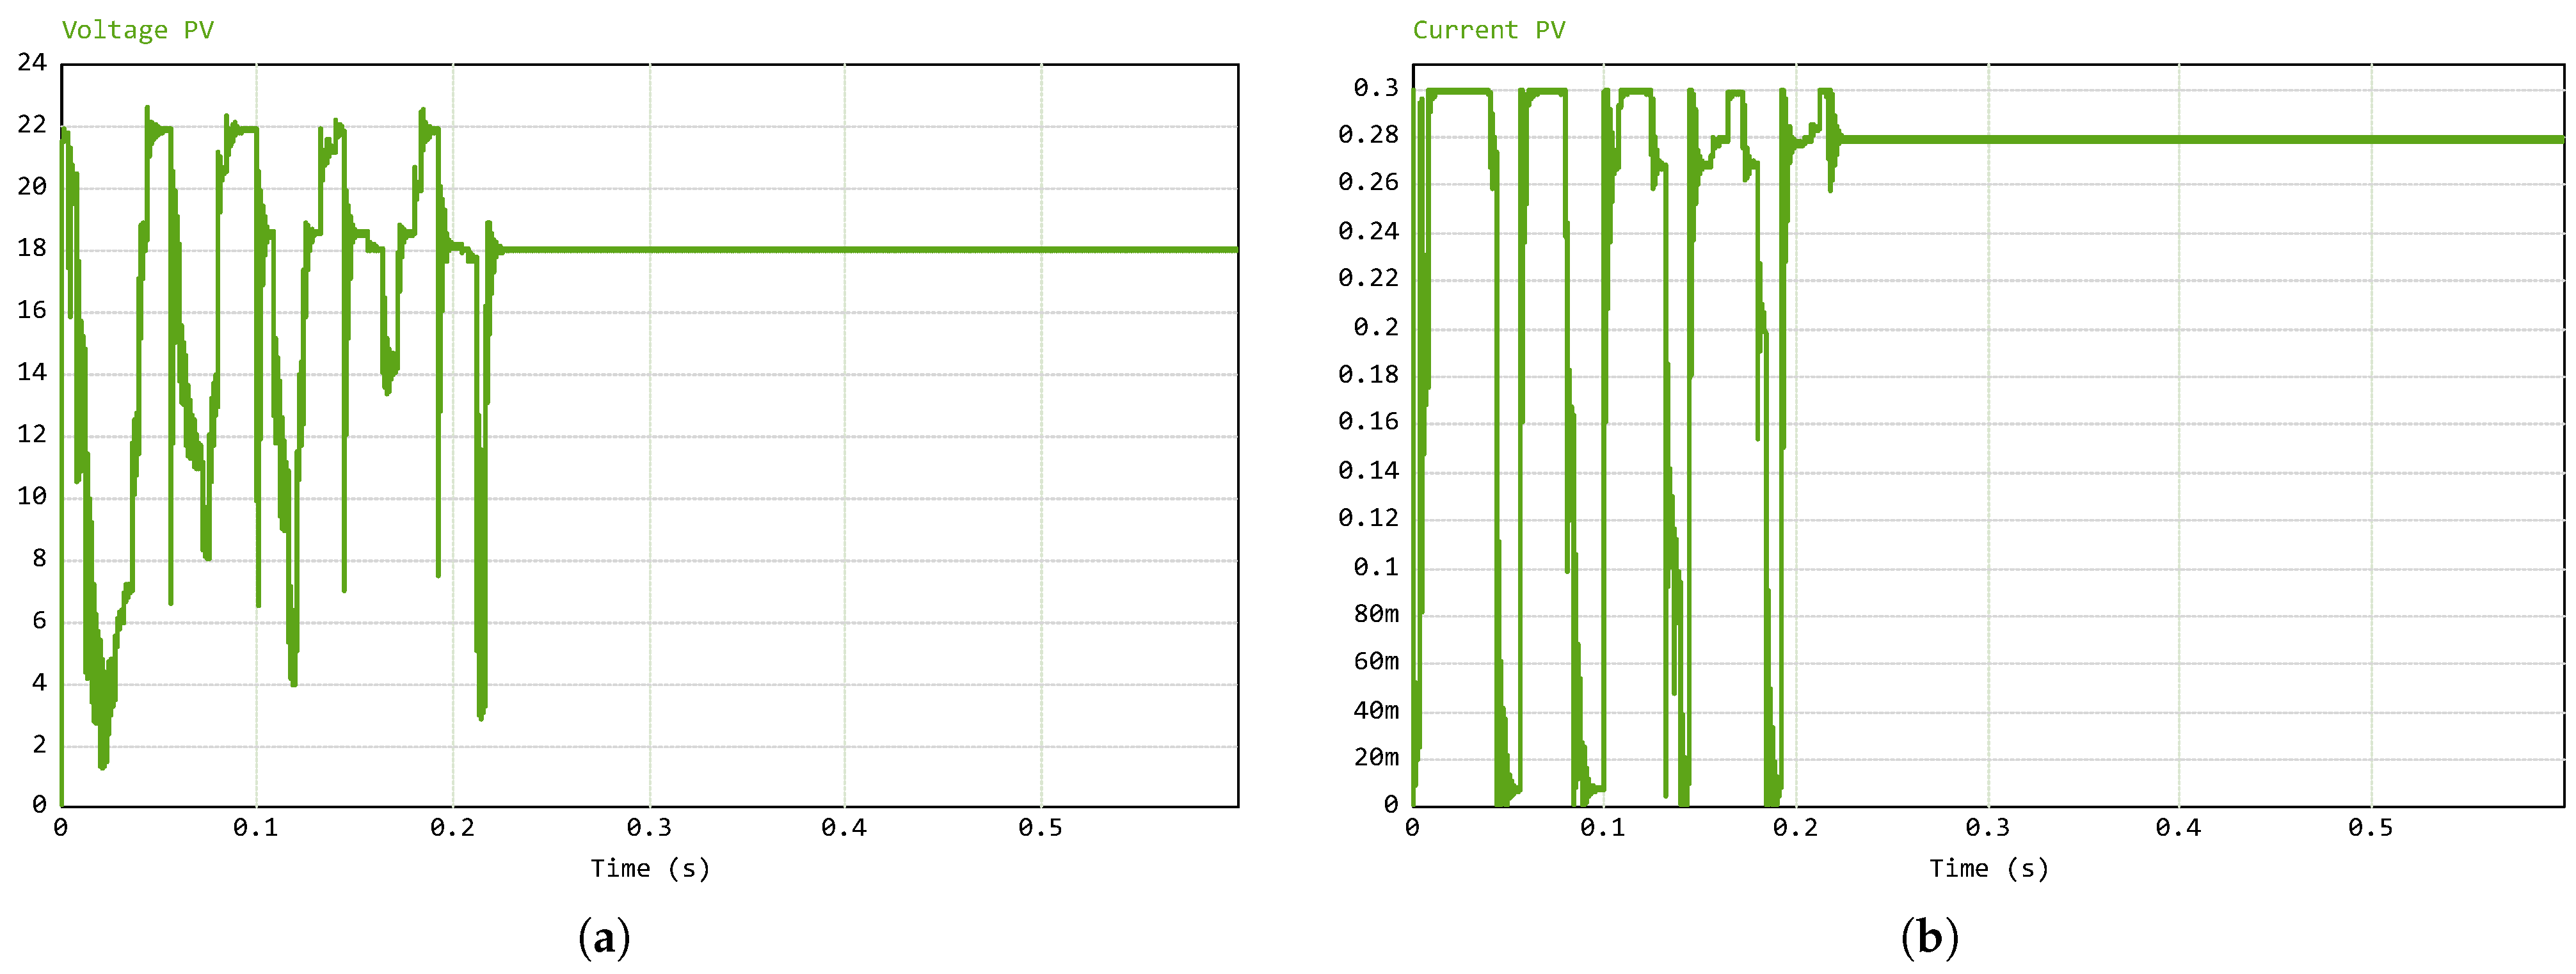
As the algorithm has stochastic characteristics, i.e., it is based on random decisions, the power extracted may vary even under the same environmental conditions. The evolution of the voltage and current is shown in Figure 25a and Figure 25b, respectively. Minor fluctuations were observed when compared with the method presented above.
Figure 25.
Variation in (a) voltage and (b) current for the traditional GTO algorithm under STCs.
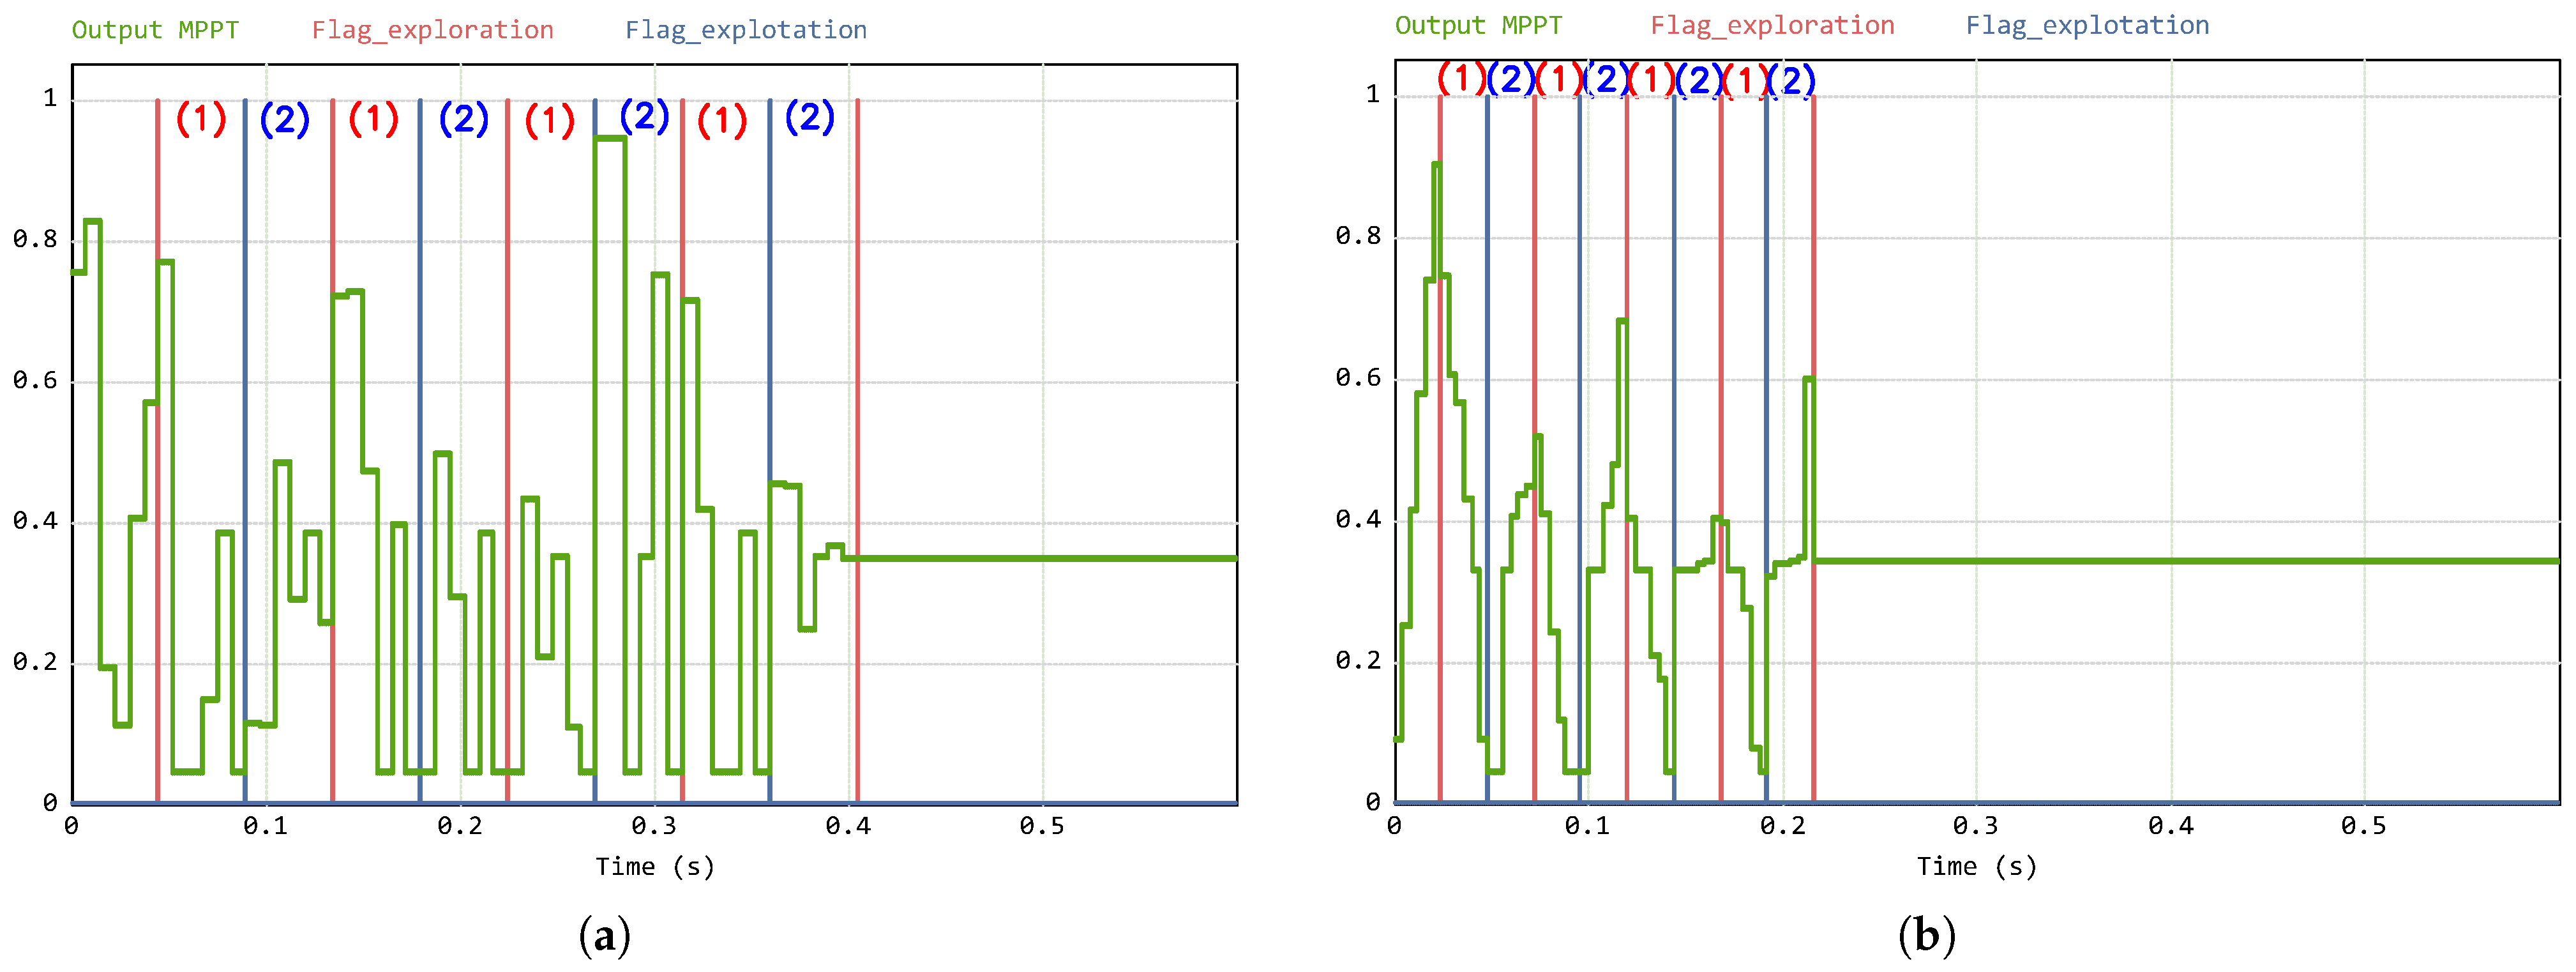
Figure 26a shows the MPPT output (duty cycle), representing the individuals tested during the first iteration, which culminated in the selection of the silverback. The figure also represents the time instants when the algorithm enters the exploration phase and the exploitation phase, indicated respectively by (1) Flag_exploration and (2) Flag_exploitation. Two main aspects stand out: the presence of many individuals reaching the extremes (maximums and minimums) as well as significant variations in the duty cycle in adjacent individuals, with operation near the extremes. Extremely low or high duty cycles are not desirable in a real converter. DC/DC converters are usually designed to operate in continuous conduction mode. Extremely low duty cycles can originate operation in discontinuous operation mode. Extremely high duty cycles may not be feasible due to losses in the converter. These sudden fluctuations increase the instability of the system and prolong the time required for the converter to reach a steady state.
Figure 26.
Output (duty cycle) of (a) GTO and (b) EnGTO, where (1) represents the exploration phase and (2) is the exploitation phase.
3.4. Proposed EnGTO
To mitigate the previously mentioned negative effects, the following adaptations were introduced to the algorithm:
- The initial population was longer generated randomly but distributed uniformly and sequentially between the lower limit (LB = 5) and upper limit (UB = 95).
- After the exploration and exploitation phases, before the individuals were evaluated, they were reorganized sequentially in descending order after the exploration phase and in ascending order after exploitation to prevent sudden changes in the duty cycle in adjacent individuals. With this, the stabilization time for the converter to reach a steady state was much shorter, allowing the algorithm’s convergence time to be significantly reduced from 7.5 ms to 4 ms.
- The parameters W and p of the exploration phase were empirically increased for better exploration capabilities. Parameter W was increased to 0.9 to prevent population stagnation. By delaying the transition to the exploitation phase, the algorithm performed a more thorough search of the P-V curve. At the same time, by balancing the transition to the “silverback-following” behavior, we achieved rapid convergence times while maintaining high stability once the GMPP was reached. The parameter p was increased to 0.08 to ensure robust global exploration in complex shading scenarios where the GMPP may have been far from the initial population distribution.
Figure 26b shows the MPPT output after implementing the proposed modifications, keeping the conditions to which the system was subject unchanged. The individuals were then organized sequentially, and although there were isolated cases, they did not tend to be at extremes. The evolution of the power, voltage and current for the algorithm with the adaptations introduced is shown in Figure 27, Figure 28a and Figure 28b, respectively. The average power extracted was 5.060 W, which represents an increase in the power extracted compared with the traditional GTO, in addition to presenting lower oscillations, being to the order of 13.7 mW (compared with 21 mW in the GTO and 54 mW in P&O).
Figure 27.
Power curve for EnGTO under STCs.
Figure 28.
Variation in (a) voltage and (b) current for EnGTO algorithm under STCs.
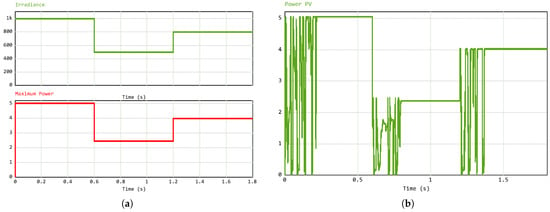
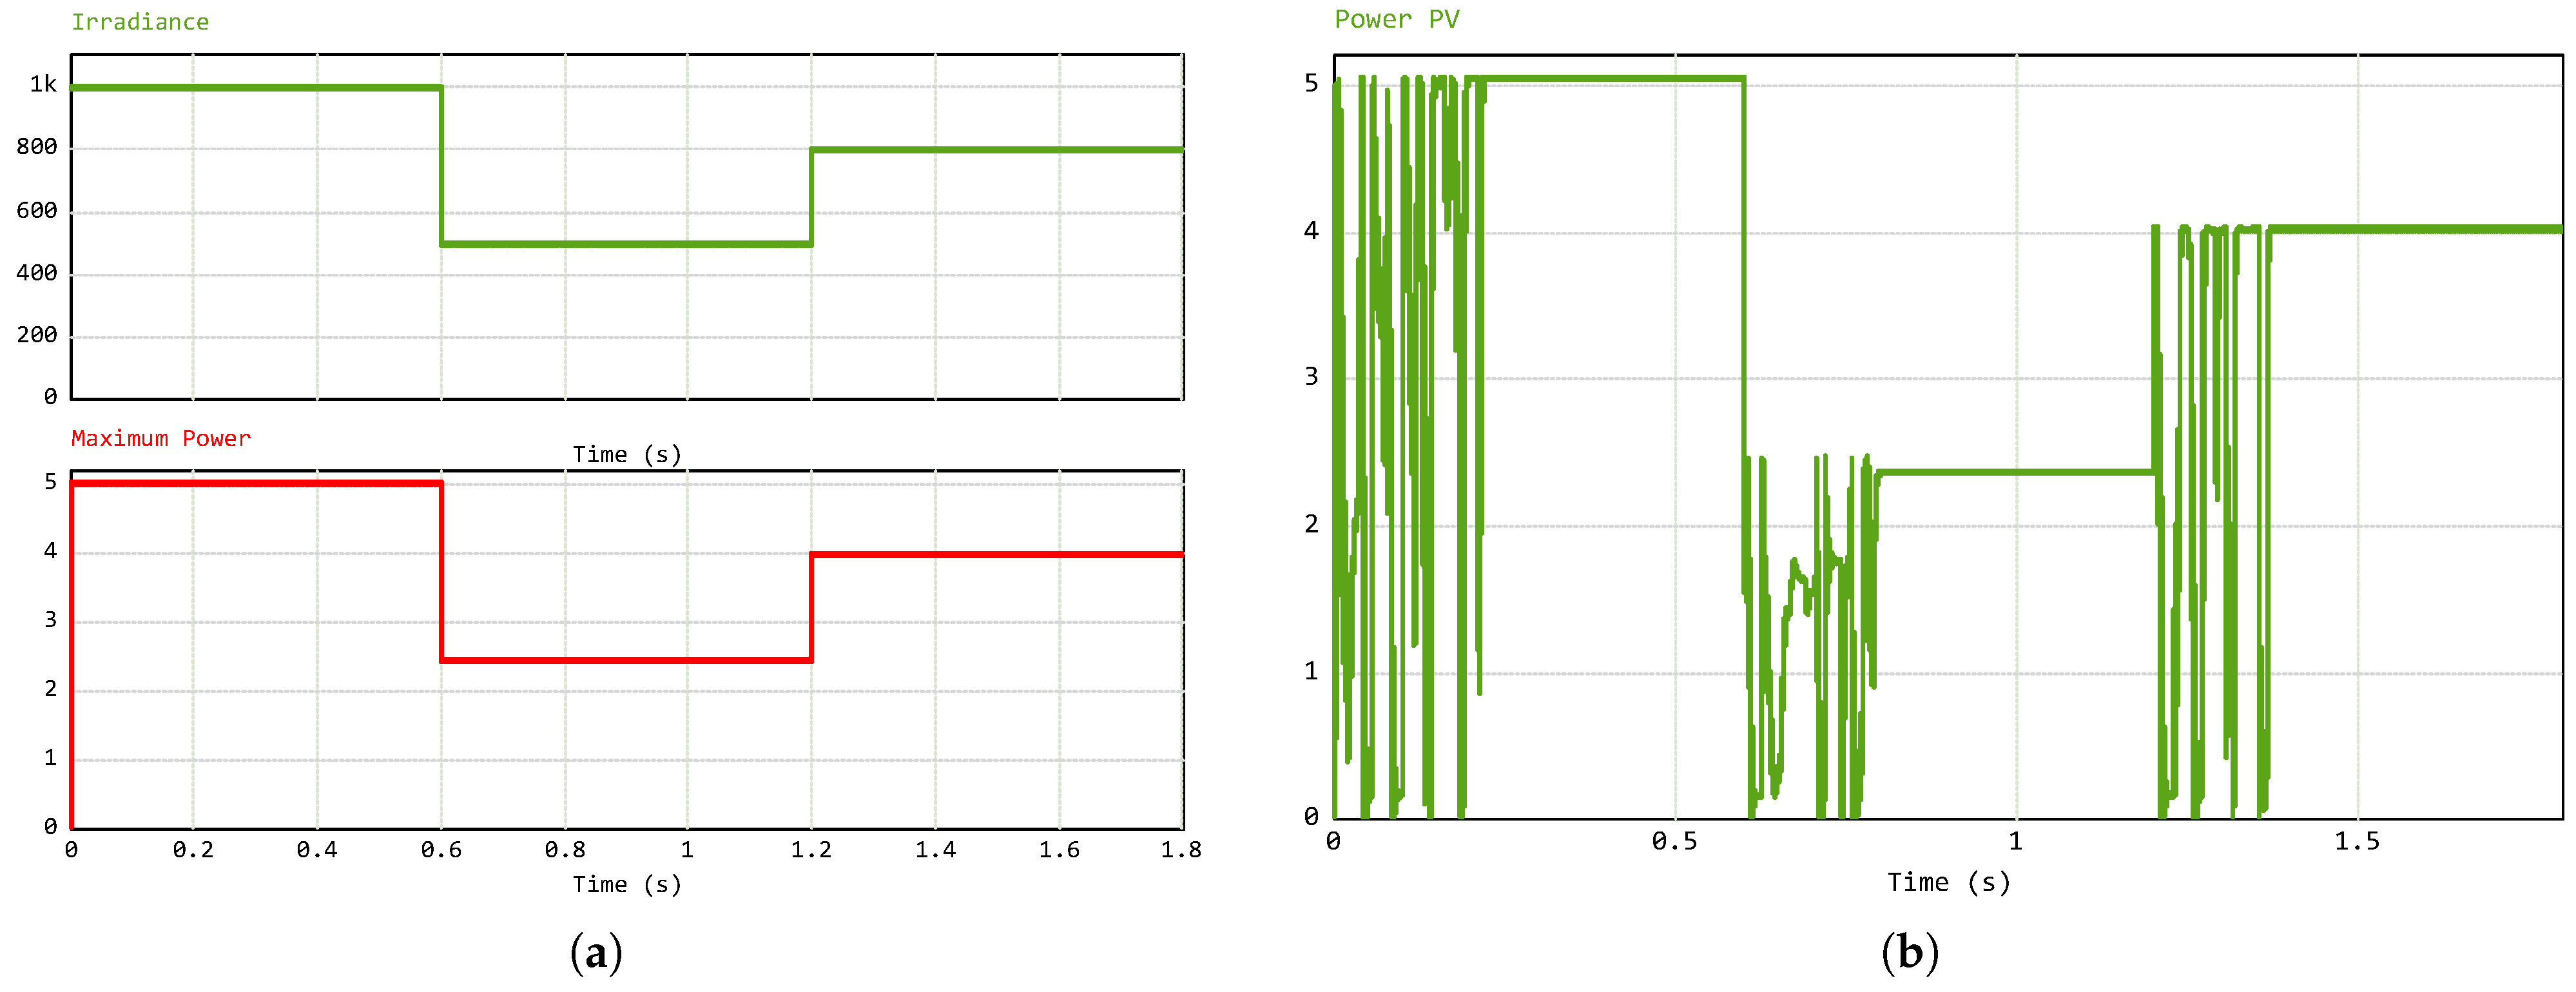
The EnGTO performance was tested for variable irradiance conditions. The same was applied to P&O but with a step time of 0.6 s (Figure 29a). The resulting power curve, shown in Figure 29b, confirms that the new search was performed successfully, as expected. Table 6 shows the best power extracted () by the GTO and EnGTO, considering different levels of irradiance, compared with the theorectical MPP ().
Figure 29.
(a) Irradiance variation and corresponding theorectical GMPP. (b) Response of EnGTO.
Table 6.
Power extracted for each irradiance level by GTO and EnGTO.
It is worth adding that an analysis was carried out regarding 13 simulations for the GTO and EnGTO algorithms at STCs, having excluded the three worst results, identified as outliers. The results obtained were as follows: (1) For the EnGTO, the average was 5.056 W, with the worst result being 4.550 W; (2) For the GTO, the average was 5.051 W, with the worst result being 3.780 W.
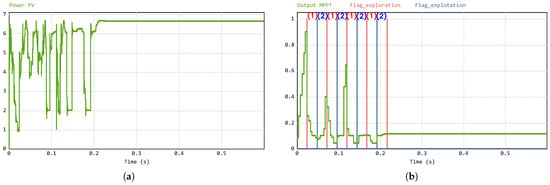
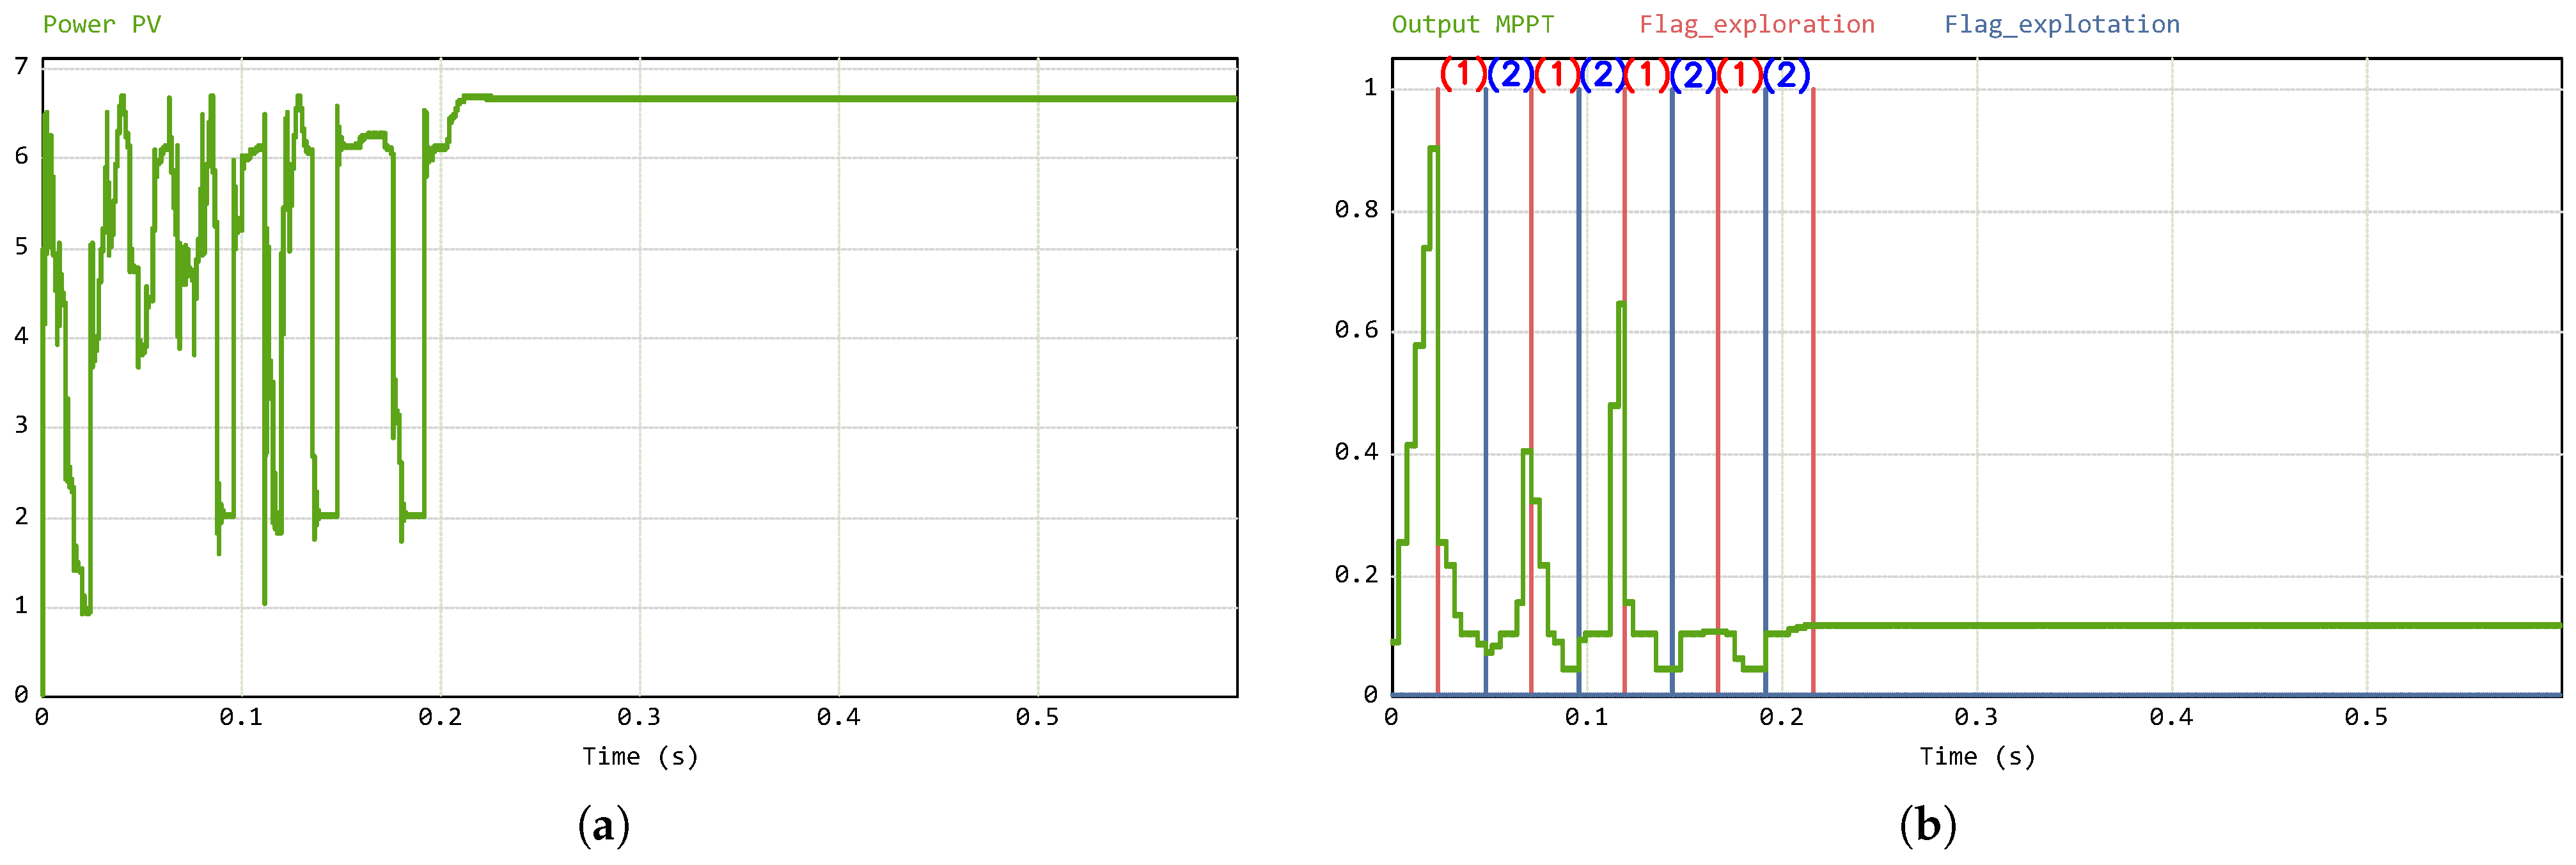
One of the previously highlighted advantages of this type of algorithm is its ability to track the GMPP even under PSCs. To validate this aspect, the same conditions described in Figure 13b were applied to the EnGTO. The evolution of the extracted power and the MPPT output are shown in Figure 30a,b. In this simulation, the average power extracted was 6.7025 W, while the GMPP value was 6.715 W, showing that the algorithm was not restricted to either of the two LMPPs, approaching the theoretical GMPP with an efficiency of 99.81%.
Figure 30.
Curves: (a) power of EnGTO and (b) respective evolution of output under PSCs, where (1) represents the exploration phase and (2) is the exploitation phase.
3.5. Comparison Between Algorithms
Based on Equation (19), which evaluates the efficiency of the algorithms, Table 7 shows the efficiencies for each level of irradiance:
Table 7.
Efficiency of different algorithms for different levels of irradiance.
The methods were also evaluated while considering the configuration of three branches in three parallels, each composed of two panels in series. The simulation was started under STCs, and after 0.6 s, the irradiance was reduced to 500 W/m2. Under these conditions, the value of was 30.40 W and 14.90 W, respectively. , as mentioned above, corresponds to the average power extracted during the steady state of the algorithm. Table 8 shows the efficiencies obtained for each algorithm, the time required to track the maximum power under STCs and the 500 W/m2 condition, as well as the ability (or inability) to identify the GMPP, even under PSCs.
Table 8.
Performance of the implemented MPPT algorithms.
In terms of efficiency, all algorithms presented high values, resulting from both the appropriate adjustment of parameters and the use of ideal components in the simulations. The least efficient algorithm was conventional P&O, which was expected, considering its simplicity of implementation. As previously mentioned, the actual assessment, without the use of mathematical equivalents, of the impact of the “gorilla” on the system contributed to the increase in convergence time in GTO methods.
In turn, the GTO-based algorithms demonstrated a clear and highly relevant advantage in practical scenarios, which is linked to their ability to efficiently track the GMPP, even under partial shading conditions. In addition, the proposed EnGTO proved to be superior to the traditional GTO, with a shorter convergence time, slighty better GMPP, greater exploration of the search space and less of a tendency for individuals to concentrate on the extremes of the population.
4. Conclusions
Growing concern about environmental issues has boosted the use of renewable energy sources, among which solar energy stands out as one of the most promising issues. One aspect worth highlighting is the impact of environmental conditions, namely temperature and, above all, irradiance, on the output power of PV panels. As already mentioned, environmental conditions are volatile, which directly influences the energy produced by the system. These constant changes impact the MPP, requiring algorithms that allow continuous and rapid adaptations to these changes.
Two techniques were explored. The first, the classic P&O method, is widely used due to its simplicity and good efficiency in stable conditions but not ideal in PSC situations. The second technique analyzed was the GTO, a recent algorithm that is still little explored in the context of MPPT. This technique demonstrated good efficiency in responding to variations in atmospheric conditions and performed satisfactorily in shading situations. In addition, modifications were introduced to the traditional GTO to overcome some limitations, which significantly reduced the time required for convergence, while maintaining excellent efficiencies and low oscillations, thus improving the overall performance of the system.
While the proposed EnGTO algorithm demonstrated significant improvements in MPPT efficiency, reaching up to 99.96% (STCs) and 99.81% (PSCs), and rapid response to fast climatic variations, certain limitations remain, requiring further investigation. The current study primarily validates the algorithm’s performance through PSIM software simulations; therefore, future research should focus on experimental validation to assess real-world computational overhead and hardware constraints. Additionally, while the EnGTO effectively mitigates population stagnation in complex shading scenarios compared with the standard GTO, exploring its integration with other intelligent techniques, such as fuzzy logic or neural networks, could further refine its adaptability to extreme environmental noise. Future work could also investigate the scalability of the EnGTO in large-scale PV plants with complex configurations to ensure robust performance across diverse industrial applications. Finally, future studies should compare the EnGTO’s performance against other state-of-the-art metaheuristics and other recent GTO variants.
Author Contributions
Conceptualization, B.S. and R.C.; methodology, B.S. and R.C.; software, B.S. and R.C.; validation, B.S. and R.C.; formal analysis, B.S. and R.C.; investigation, B.S. and R.C.; resources, B.S. and R.C.; data curation, B.S. and R.C.; writing—original draft, B.S. and R.C.; writing—review and editing, B.S. and R.C.; visualization, R.C.; supervision, R.C.; project administration, R.C. All authors have read and agreed to the published version of the manuscript.
Funding
This research received no external funding.
Data Availability Statement
The data is contained within this article.
Conflicts of Interest
All the authors declare that they have no competing financial interests or personal relationships that could have influenced the work reported in this paper.
Abbreviations
The following abbreviations are used in this manuscript:
| DC | Direct current |
| GMPP | Global maximum power point |
| GTO | Gorilla Troops Optimizer |
| IEA | International Energy Agency |
| LMPP | Local maximum power point |
| MPP | Maximum power point |
| MPPT | Maximum power point tracking |
| P&O | Perturb and observe |
| PSC | Partial shading condition |
| PV | Photovoltaic |
| STC | Standard test condition |
References
- Hussein, J.A. Perspectives on Solar Energy. Technology Analysis. In Proceedings of the 2024 27th International Conference on Soft Computing and Measurements (SCM), St. Petersburg, Russia, 22–24 May 2024; IEEE: Piscataway, NJ, USA, 2024; pp. 62–68. [Google Scholar] [CrossRef] [Scilit]
- Endiz, M.S.; Gökkuş, G.; Coşgun, A.E.; Demir, H. A Review of Traditional and Advanced MPPT Approaches for PV Systems Under Uniformly Insolation and Partially Shaded Conditions. Appl. Sci. 2025, 15, 1031. [Google Scholar] [CrossRef] [Scilit]
- Kalogirou, S.A. Solar Energy Engineering: Processes and Systems; Elsevier: Oxford, UK, 2009. [Google Scholar] [CrossRef] [Scilit]
- Mazumdar, D.; Sain, C.; Biswas, P.K.; Sanjeevikumar, P.; Khan, B. Overview of Solar Photovoltaic MPPT Methods: A State of the Art on Conventional and Artificial Intelligence Control Techniques. Int. Trans. Electr. Energy Syst. 2024, 2024, 8363342. [Google Scholar] [CrossRef] [Scilit]
- Prajapati, S.; Fernandez, E. Effect of the Positioning of Single and Double Bypass Diodes in a PV String on Its Reliability. In Proceedings of the 2020 International Conference on Computer, Electrical & Communication Engineering (ICCECE), Kolkata, India, 17–18 January 2020; pp. 1–5. [Google Scholar] [CrossRef] [Scilit]
- Lyu, G.; Soomar, A.M.; Shah, S.H.H.; Shaikh, S.; Musznicki, P. Maximum power point tracking strategies for solar PV systems: A review of current methods and future innovations. Results Eng. 2025, 28, 107227. [Google Scholar] [CrossRef] [Scilit]
- Bollipo, R.B.; Mikkili, S.; Bonthagorla, P.K. Hybrid, optimal, intelligent and classical PV MPPT techniques: A review. CSEE J. Power Energy Syst. 2021, 7, 9–33. [Google Scholar] [CrossRef] [Scilit]
- Katche, M.L.; Makokha, A.B.; Zachary, S.O.; Adaramola, M.S. A Comprehensive Review of Maximum Power Point Tracking (MPPT) Techniques Used in Solar PV Systems. Energies 2023, 16, 2206. [Google Scholar] [CrossRef] [Scilit]
- Mohapatra, A.; Nayak, B.; Das, P.; Mohanty, K.B. A review on MPPT techniques of PV system under partial shading condition. Renew. Sustain. Energy Rev. 2017, 80, 854–867. [Google Scholar] [CrossRef] [Scilit]
- Nagadurga, T.; Raju, V.D.; Barnawi, A.B.; Bhutto, J.K.; Razak, A.; Wodajo, A.W. Global MPPT optimization for partially shaded photovoltaic systems. Sci Rep. 2025, 15, 10831. [Google Scholar] [CrossRef] [Scilit]
- Yousaf, M.Z.; Koondhar, M.A.; Zaki, Z.A.; Ahmed, E.M.; Alaas, Z.M.; Mahariq, I.; Guerrero, J.M. Improved MPPT of solar PV Systems under different Environmental conditions utilizes a Novel Hybrid PSO. Renew. Energy 2025, 244, 122709. [Google Scholar] [CrossRef] [Scilit]
- Abdollahzadeh, B.; Soleimanian Gharehchopogh, F.; Mirjalili, S. Artificial gorilla troops optimizer: A new nature-inspired metaheuristic algorithm for global optimization problems. Int. J. Intell. Syst. 2021, 36, 5887–5958. [Google Scholar] [CrossRef] [Scilit]
- Liu, C.; Wu, B.; Zhu, L. A Labor Division Artificial Gorilla Troops Algorithm for Engineering Optimization. Biomimetics 2025, 10, 127. [Google Scholar] [CrossRef] [Scilit]
- Rihan, M.; Sayed, A.; Abdel-Rahman, A.B.; Ebeed, M.; Alghamdi, T.A.H.; Salama, H.S. An artificial gorilla troops optimizer for stochastic unit commitment problem solution incorporating solar, wind, and load uncertainties. PLoS ONE 2024, 19, e0305329. [Google Scholar] [CrossRef] [Scilit]
- Gude, M.K.; Salma, S. Artificial Gorilla Troops Optimizer for Tuning Power System Stabilizer Control Parameters. In Proceedings of the 2021 IEEE 2nd International Conference on Electrical Power and Energy Systems (ICEPES), Bhopal, India, 10–11 December 2021; pp. 1–5. [Google Scholar] [CrossRef] [Scilit]
- Ginidi, A.; Elattar, E.; Shaheen, A.; Elsayed, A.; El-Sehiemy, R.; Dorrah, H. Optimal Power Flow Incorporating Thyristor-Controlled Series Capacitors Using the Gorilla Troops Algorithm. Int. Trans. Electr. Energy Syst. 2022, 2022, 9448199. [Google Scholar] [CrossRef] [Scilit]
- Fathy, A.; Yousri, D. An efficient artificial gorilla troops optimizer-based tracker for harvesting maximum power from thermoelectric generation system. Appl. Therm. Eng. 2023, 234, 121290. [Google Scholar] [CrossRef] [Scilit]
- Abdelaal, A.K.; Alhamahmy, A.I.A.; Attia, H.E.D.; El-Fergany, A.A. Maximizing solar radiations of PV panels using artificial gorilla troops reinforced by experimental investigations. Sci. Rep. 2024, 14, 3562. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Mohamed, N.; Hamed, H.A. Gorilla troops optimization-based MPPT for augmented performance of photovoltaic systems. AIP Conf. Proc. 2023, 2776, 050017. [Google Scholar] [CrossRef] [Scilit]
- Gomaa, I.; Sabry, H.; Saeid, N.; Sayed, H. A Novel Enhanced Gorilla Troops Optimizer Algorithm for Global Optimization Problems. Int. J. Ind. Eng. Prod. Res. 2023, 34, 1–9. [Google Scholar] [CrossRef]
- Mostafa, R.R.; Gaheen, M.A.; ElAziz, M.A.; Al-Betar, M.A.; Ewees, A.A. An improved gorilla troops optimizer for global optimization problems and feature selection. Knowl.-Based Syst. 2023, 269, 110462. [Google Scholar] [CrossRef] [Scilit]
- Hassan, M.H.; Kamel, S.; Mohamed, A.W. Enhanced gorilla troops optimizer powered by marine predator algorithm: Global optimization and engineering design. Sci. Rep. 2024, 14, 7650. [Google Scholar] [CrossRef] [Scilit]
- Abdel-Basset, M.; El-Shahat, D.; Sallam, K.M.; Munasinghe, K. Parameter extraction of photovoltaic models using a memory-based improved gorilla troops optimizer. Energy Convers. Manag. 2022, 252, 115134. [Google Scholar] [CrossRef] [Scilit]
- Gacem, A.; Kechida, R.; Bekakra, Y.; Jurado, F.; Sameh, M.A. Hybrid cuckoo search-gorilla troops optimizer for optimal parameter estimation in photovoltaic modules. J. Eng. Res. 2025, 13, 3334–3351. [Google Scholar] [CrossRef] [Scilit]
- Ghith, E.S.; Tolba, F.A.A. Tuning PID controllers based on hybrid arithmetic optimization algorithm and artificial gorilla troop optimization for micro-robotics systems. IEEE Access 2023, 11, 27138–27154. [Google Scholar] [CrossRef] [Scilit]
- Femia, N.; Petrone, G.; Spagnuolo, G.; Vitelli, M. Optimization of perturb and observe maximum power point tracking method. IEEE Trans. Power Electron. 2005, 20, 963–973. [Google Scholar] [CrossRef] [Scilit]
- Ahmad, R.; Murtaza, A.F.; Sher, H.A. Power tracking techniques for efficient operation of photovoltaic array in solar applications—A review. Renew. Sustain. Energy Rev. 2019, 101, 82–102. [Google Scholar] [CrossRef] [Scilit]
- Hussien, A.G.; Bouaouda, A.; Alzaqebah, A.; Kumar, S.; Hu, G.; Jia, H. An in-depth survey of the artificial gorilla troops optimizer: Outcomes, variations, and applications. Artif. Intell. Rev. 2024, 57, 10838. [Google Scholar] [CrossRef] [Scilit]
- You, J.; Jia, H.; Wu, D.; Rao, H.; Wen, C.; Liu, Q.; Abualigah, L. Modified Artificial Gorilla Troop Optimization Algorithm for Solving Constrained Engineering Optimization Problems. Mathematics 2023, 11, 1256. [Google Scholar] [CrossRef] [Scilit]
- Toumi, D.; Benattous, D.; Ibrahim, A.; Abdul-Ghaffar, H.I.; Obukhov, S.; Aboelsaud, R.; Labbi, Y.; Diab, A.A. Optimal design and analysis of DC–DC converter with maximum power controller for stand-alone PV system. Energy Rep. 2021, 7, 4951–4960. [Google Scholar] [CrossRef] [Scilit]
- Scott, D. Box–Muller transformation. Wiley Interdiscip. Rev. Comput. Stat. 2011, 3, 177–179. [Google Scholar] [CrossRef] [Scilit]
- Box, G.E.P.; Muller, M.E. A note on the generation of random normal deviates. Ann. Math. Stat. 1958, 29, 610–611. [Google Scholar] [CrossRef] [Scilit]

Disclaimer/Publisher’s Note: The statements, opinions and data contained in all publications are solely those of the individual author(s) and contributor(s) and not of MDPI and/or the editor(s). MDPI and/or the editor(s) disclaim responsibility for any injury to people or property resulting from any ideas, methods, instructions or products referred to in the content. |
© 2026 by the authors. Licensee MDPI, Basel, Switzerland. This article is an open access article distributed under the terms and conditions of the Creative Commons Attribution (CC BY) license.