


Abstract
This numerical study investigates steady separated flow past a grooved circular cylinder within the Reynolds number range , comprising variations in groove depth () and spacing (). The groove width () is kept constant, while h/w varies across four levels () and across five angles (). The results exhibit strong agreement with unbounded flow data, confirming blockage independence across the examined regime. Detailed analysis shows that has a stronger influence than on surface-pressure-dependent variables (, , , ) and wake-defining parameters (, , , ), underscoring the dominant role of in rectilinear groove aerodynamics. In this regard, a critical spacing of is observed, beyond which the sensitivity of the parameters toward the cylinder configuration decreases. Thus, significant flow control and drag reduction are attained for at the lowest spacing , regardless of the groove’s . Among these, the streamwise-oriented variables, , , , , and , exhibit monotonic trend with respect to and are modeled using power-law relations. The models for and exhibit significant accuracy with across all values considered, while it is 0.89–0.98 for , , and , depending on . Transverse-oriented parameters () vary non-monotonically. In addition, it is found that the streamwise locations of maximum wake width () and minimum velocity () are unaffected by the grooved cylinder configuration.
1. Introduction
Research shows that the steady separated flow past circular cylinder at low Reynolds numbers ()—particularly in the range of —is largely two-dimensional and characterized by an attached closed recirculation region, which is stable, stationary, and symmetric with respect to the cylinder centerline [1,2,3,4]. Particularly, this flow regime is known for its fundamental significance in understanding laminar separation bubbles, wake formation and instability, and vortex dynamics around bluff bodies [1,5]. The knowledge derived based on the vorticity dynamics have been applied to harvest energy from wind-induced oscillations about a circular rod, for instance, the vortex-based wind turbines [6]. The consequences of the vortex-induced vibrations on the bluff body may become worse in few cases. Advanced nonlinear devices such as energy sinks have been employed to suppress the vortex-induced vibration [7,8,9]. Hence, a basic study on the flow control mechanism is essential from the steady flow perspective. In fact, the drag forces are considerably larger at lower Re, implying an enhanced interaction of the flow with the bluff body. This might be a reason the vast literature, including both experimental and numerical investigations spanning decades, is pertinent to the investigation of symmetric wakes in this regime [4,10,11,12,13]. Those studies have extensively investigated the effect of and cross sections of the cylinder, including circular, square, triangular, semicircular, etc., on the characteristics of bluff body wakes [1]. Among them, circular cylinders are the most commonly employed bluff bodies due to their finite and continuous curvature, revealing complex flow phenomena. Besides, the flow evolution is highly sensitive to , compared to the surface roughness, free-stream turbulence, and other secondary factors. In this light, earlier studies have modified the cylinder surface using elements such as vortex generators and grooves, and investigated its efficiency in terms of drag reduction and passive flow control applications [5]. It follows that aerodynamic analysis of laminar separated flow past a circular cylinder in the range —owing to relatively higher interaction between the surface and the fluid—may provide better insight into the factors influencing the flow field alterations induced by varying the cylinder geometry. Aligned with this perspective, the present work examines steady separated flow about grooved cylinders configured at different groove depths and spacings.
Topology of the Steady Wake
Earlier studies on steady separated flow past bluff bodies primarily focused on the characteristics of the stationary wake formed in the rear portion of the cylinder [1]. Due to the symmetric nature of the flow, a pair of identical occurs above and below the centerline. Thus, two oppositely signed vortices—represented by dotted closed lines with arrows—of equal strength are formed, commonly referred to as “twin vortices” [4]. Research indicates that the symmetrical flow structure is vital in exploring the wake dynamics, drag characteristics, and flow-induced vibrations [3]. The wake characteristics, including its length, width, and core position, are known to govern the extent of recirculation region and the base pressure, thereby exhibiting direct influence on the aerodynamic performance [3]. Figure 1 depicts the topology of the steady wake formed about a circular cylinder, grooved or non-grooved. The laminar boundary layer evolving downstream to the front stagnation point () tends to detach from the surface due to the adverse pressure gradient built up in the rear portion of the cylinder. The onset of separation, denoted as , is thought to originate at the base stagnation point (), approximately at [12]. In fact, the cylinder geometry and govern prominently, while the surface roughness, free-stream turbulence, incidence angle, and a few other secondary factors tend to moderately alter [2,3]. The streamlines departing from top and bottom evolve in both streamwise and normal directions, identified as the isolines of zero-streamfunction () in Figure 1. These lines tend to become the boundary of the wake flow, separating the irrotational free-stream and the recirculating flow within the wake. In the figure, the latter is denoted using the dotted lines with an arrow, where each line represents constant vorticity, . Further downstream to , the isolines of converge toward the centerline. The wake flow stagnates at the point where the streamlines intersect, marking the end of the recirculation region, denoted as in the figure. It follows that the wake length, corresponds to the streamwise distance between and , at which the streamwise velocity component is zero [12]. Similarly, the maximum vertical extent of the separation streamlines determines the wake width, . It must be remarked that, post the reattachment, the trajectory of streamlines deviate toward , aligning with the cylinder centerline. Given this, it is evident that the twin vortices are separated by a thin region of irrotational flow, where the mass flux is almost 0. In the figure, the zero isolines of both the streamwise () and normal () components are shown. These two lines originate at and eventually merge with the isolines that run parallel to the centerline. It is worth noting that these two lines intersect at the core of the stationary wake. Thus, the streamwise and normal locations of the intersection point, measured from , tend to be the abscissa () and ordinate () of the vortex core, respectively. In addition to the above-mentioned topological parameters of the stationary wake, Figure 1 also shows the notations adopted for the groove configuration. Conventionally, the angle is measured in the clockwise direction, such that and denotes and , respectively. The groove aspect ratio is defined as , where denotes the groove depth (aligned radially) and represents the groove width (oriented parallel to ). The groove spacing () is accounted for as the angle between the axes of consecutive grooves. Thus, the number of grooves () along the circumference varies based on .
Figure 1.
Schematic of steady separated flow past the circular cylinder with rectilinear grooves, illustrating the topology of the symmetric wake. In the figure, solid lines represent the dividing streamline (), which defines the wake centerline and boundary. Long-dashed and dotted lines indicate the contours of zero streamwise () and normal () velocity components, respectively, while short-dashed lines show contours of constant vorticity. Additionally, the dash-dotted line denotes the vertical and horizontal axes of the cylinder.
Table 1 presents the details of investigations carried out on the flow past a grooved cylinder, along with the factors examined in the respective study. The data in Table 1 reveals that the grooves in a circular cylinder—either spanwise or streamwise—are intended for flow control applications, where drag reduction remains the principal focus. Except for a few recent studies, most of the research works were carried out in the subcritical regime for sphere/circular cylinder, , where the drag force monotonically decreases with increasing . Research indicates the presence of highly complex flow features within this regime, including unsteady vortex shedding and laminar-to-turbulent transition. From Table 1, it is evident that the earlier studies employed both single and multiple grooves. In the former case, the significance of the groove’s angular position was investigated. The findings suggested that the groove is efficient when placed within the range of , measured clockwise from , in terms of drag reduction and flow control.
Table 1.
Earlier studies on flow past a grooved cylinder.
From Table 1, it is evident that earlier studies have incorporated either fully or partially grooved configurations. In the former, the grooves are distributed uniformly along the cylinder; the groove’s , , and shape, including curved (arc, sinusoidal, etc.) and rectilinear (triangular, rectangular, etc.) geometries, were examined. Particularly, the experimental study conducted by Leung et al. [18] determined an optimal , which denotes the angle subtended between the edges of the triangular grooves for efficient drag reduction and flow control, whereas, in the latter case, a finite number of grooves occupied a segment of the cylinder and were defined using the angle between the axes of first and last grooves, referred to as the “groove angle” (). Notably, the numerical study by Babu and Mahesh [19] and the experimental study by Seo et al. [20] have employed biomimetic groove shapes. The first group of researchers employed a fully grooved cylinder, resembling the cactus plant, and the latter authors investigated a partially grooved cylinder, where the groove shape was likely inspired by the tail segment of a fish species, though the rectangular groove configuration has been widely tested compared to other shapes like V, U, or arc. The common choice in this regard likely rests on the effective cavity flows occurring within the rectangular cavities at optimal angle or free-stream velocity.
The above inferences suggest that, although various factors related to the grooves have been investigated, the information on optimum spacing between consecutive grooves remains a research gap. In case of grooved cylinder—either full or partial—the grooves are positioned in tandem with respect to the flow. Although one or more grooves may be effectively located within [14,20], it is worth noting that the proximity of the adjacent groove can influence the effectiveness of neighboring grooves, depending on the spacing between them. Besides, the contribution of the groove dimension, either or , could not be neglected as a whole. Research indicates that the grooves with a fully developed recirculation flow—generally referred to as the “cavity flow”—inside them tend to be more effective [14,24]. It is thought that the steady cavity flow occurs in a sufficiently deeper rectangular cavity [26].
In line with these queries, the present study aspires to investigate the influence of varying groove configurations—both in terms of dimension and spacing—on drag reduction and flow characteristics. In this context, rectangular/square grooves are chosen, which might exhibit characteristics comparable to the established cavity flow. Further, the present problem is simplified by considering a steady laminar separated flow in the range of . By doing so, more thrust is given to analyze the effect of change in cylinder geometry on the wake characteristics that promote instability at higher . Given this, the present study addresses the following objectives:
- Analyzing the effect of groove spacing on surface variables, , , , , , and , which depend on the modifications in the pressure field () adjacent to the surface, and field parameters, , , , , and .
- Determining the critical at which the sensitivity of the variables or parameters of interest shifts significantly.
- Modeling the consistent trends in the above-mentioned variables against , with the modeling factors as a function of .
2. Methodology
Consistent with the study’s objective, this work incorporates a circular cylinder having rectilinear (square or rectangular) grooves configured across four groove depths () and five groove spacings (). Here, h is characterized by the aspect ratio h/w at constant width, and is varied between and . In order to avoid overlap between closely spaced grooves at , the cylinder diameter () is set to . Given this, the range of diameter-based Reynolds numbers () examined in this study spans the steady separation regime: . It must be noted that the non-grooved smooth cylinder is considered as the baseline in this work.
2.1. Groove Configurations
The details of various groove configurations are given in Table 2. With being constant for all cylinder configurations considered in this study, the cavity-like rectilinear grooves are referred to based on the value of h: shallow (), square (), deep (), and deeper (). Therefore, the following discussions remain valid across the above four groove configurations. In the table, the maximum number of grooves is given alongside each , where it is evident that the groove count decreases linearly with increasing . In Figure 1, is the angle subtended by the midpoints of consecutive grooves, whose edges are connected by the non-grooved segment of the cylinder. In this context, the arc length of the non-grooved portion between the adjoining grooves is simply the difference between the arc length subtended by and the groove width. The arc length and the overall wetted area of the non-grooved segments decrease with decreasing . The data given in Table 2 are consistent with this notion, revealing that the above two measures for the grooved cylinder are lowest for . Furthermore, it is evident that the net area occupied by the grooves in this case is nearly of the total area, which is higher than the cumulative of non-grooved portions of the cylinder. In contrast, the aggregate area of the grooves placed at is approximately of the total area of the smooth cylinder. It follows that, for higher the grooved cylinder is configured with a lesser number of grooves and dominantly covered by the non-grooved portion. As a result, the flow field might be less perturbed compared to the grooved cylinder having closely spaced grooves. In this scenario, it is likely that the results of increasing tend to approach the baseline value. It is worth mentioning that, for all configurations of the grooved cylinder, front and rear stagnation points are located in the non-grooved portions.
Table 2.
Details of the grooved cylinder configurations considered in the present study.
2.2. Computational Domain
Figure 2 illustrates the details of the computational domain employed in the present study. Figure 2a shows the outline of the domain, which is parted into 240° and 120°, respectively, to resolve the free-stream and wake flow at varying grid resolutions. The partitioning is intended to achieve efficient mesh distribution while keeping the overall node count under control. Earlier studies have indicated that, for , the boundary layer tends to separate approximately between and , measured downstream to the front stagnation point of the circular cylinder. The discrepancy in the separation points was attributed to the domain blockage (), estimated as the ratio of the domain width to the cylinder diameter. Besides, the aforementioned range of separation angles from the numerical studies complies with the findings of an experimental study on unbounded () steady separated flow about a circular cylinder [2,4]. Thus, it is assumed against this background that the wake region in the rear half of the cylinder, formed at the low-Re regime (), spreads approximately symmetrically about the centerline. Considering numerical error sources such as blockage, mesh counts, etc., a relaxation of is accounted. Thus, the wake region in the present domain is assumed to occupy (a total of ) about the centerline. Eventually, the remaining portion of the domain (240°) is designated as the free-stream, which is less likely to be perturbed by the wake flow. It must be reminded that the highest of the present range () is well within the steady separated flow regime considered in the literature. Therefore, the designated domain configuration might not require further modification to ensure valid results. Prominently, the factors and tend to govern the wake characteristics of steady separated flow about a circular cylinder [12]. It is worth mentioning that the cylinder and the domain are concentric. The domain blockage in the present study is approximately 0.016, which is nearly 13 times larger than the lowest value of (unbounded flow) reported in the literature pertaining to numerical simulation of laminar flow past the circular cylinder. However, in the numerical study by Sen et al. [12], the authors have demonstrated that incorporating slip wall boundary conditions up to yields results equivalent to those of unbounded flow. Furthermore, it was indicated that the values of the field variables, such as , etc., remain almost constant for . It follows that the blockage-independent (or unbounded flow) results warrant either a sufficiently large domain or free-stream-like boundary conditions. In this regard, the present study attempts to implement the latter.
Figure 2.
Details of the computational domain used in the present study. (a) Domain outline showing the boundary conditions and interior partitioning; (b) non-Cartesian quadrilateral structured mesh inside the computational domain; cell size distribution within and vicinity of the groove located in (c) the free-stream region and (d) the wake region.
2.3. Boundary Conditions
The details of the boundary conditions imposed on the domain edges are shown in Figure 2a. Conventionally, the free-stream direction is from the left to the right of the computational domain. The upstream and downstream far-field extents, with respect to the cylinder, are defined using Dirichlet and Neumann boundary conditions, respectively. The former is named as “Velocity Inlet” (solid line), and the latter is referred to as “Outflow” (dashed line). Herein, the tags of the far-field boundaries reflect the terminology used in ANSYS Fluent® 2024 R2 solver [27]. Since the domain inlet is non-Cartesian by design, one-dimensional vector components are imposed to ensure a uniform flow parallel to the domain centerline. Consequently, the streamlines in the free-stream region tend to comply with the Eulerian framework of the finite volume method. On the surface of the cylinder, no-slip wall conditions are imposed. At the domain exit, the mass conservation is ensured by imposing a zero-diffusion flux condition, [28]. In this context, indicates the component of a vector normal to the Outflow edge. Comparably, in the numerical study of steady flow past the circular cylinder, Fornberg [28] implemented a boundary condition with zero normal derivative of streamfunction () at the downstream far field. It was stated that this boundary condition is more effective at low , resulting in parallel equilines of at the outlet boundary, which indicates an unperturbed free-stream. In addition, the experimental study by Coutanceau and Bouard [29] on steady separated flow past the circular cylinder demonstrated that, in an unbounded flow () at , the wake extends nearly downstream to the base of the cylinder. Against this background, the Outflow boundary is placed approximately 25D downstream of the rear end of the cylinder. Also, the ANSYS Fluent® solver recommends that the Outflow boundary be positioned sufficiently away from the wake-generated disturbances [27]. By doing so, it is thought that this boundary condition is less likely to perturb the upstream flow and minimize the probability of reversed mass flow due to unprecedented pressure fluctuations. Therefore, it is asserted that the downstream far field is positioned sufficiently far to satisfy the solver requirements, resulting in an unperturbed free-stream at the Outflow boundary.
2.4. Mesh Distribution
The domain configuration and the mesh generation are carried out using the Gambit 2.4.6 software, which is a pre-processing companion tool distributed along with the commercial CFD solver, ANSYS Fluent®. Figure 2b shows the structured distribution of quadrilateral finite volume cells, generated with radially varying cell size. Specifically, the figure evinces sparse and concentrated mesh distribution in the free-stream and wake region, respectively. Figure 2c,d provides an exaggerated view of the mesh near the grooved cylinder, illustrating the mesh distribution within the grooves, each facing the free-stream and wake partitions, respectively. From the figures, it is evident that the node resolution in the groove shown in the former figure is relatively coarser than that in the latter. However, it is worth mentioning that the cell size variation in the direction normal to the cylinder surface is consistent in both partitions. The details of the cell size and corresponding node count across the domain and along the cylinder are given in Table 3a and Table 3b, respectively. For the present study, three mesh variants are generated: Mesh-I (coarse), Mesh-II (medium), and Mesh-III (fine). Similarly, the node resolution along the cylinder surface is altered within the range , where indicates the angle between consecutive nodes. Research indicates that, in steady laminar flow, the angular gradients within the attached boundary layer—formed between the front stagnation point and —are moderate and predictable [3], whereas beyond , the gradients along the surface of the cylinder tend to fluctuate based on the wake characteristics. Given this, the rear half of the cylinder—corresponding to the partition of the domain—is allocated with relatively higher node resolution (or lower ) compared to the front portion, which extends for . Moreover, it is thought that the finite volume method permits variable node/cell spacing based on the local flow gradients.
Table 3.
(a) Cell size and node distribution across the domain. (b) Cell size and node distribution along the cylinder.
2.5. Mesh Validation and Convergence
Research shows that the presence of grooves influences the flow characteristics on the cylinder surface and downstream to it as well [16,25]. In this light, the mesh validation and convergence in the present study involve optimizing both the grid resolution within the domain and along the cylinder surface. Regarding the former requirement, the field parameters, such as the position of the vortex core and wake boundary, are examined across three mesh variants: coarse (Mesh-I), medium (Mesh-II), and fine (Mesh-III), whereas the latter is attained by examining the surface variables, and , obtained by varying the node resolutions in the free-stream () and wake-facing () segments of the cylinder. In this context, three combinations of and are considered: , ; , ; and , . Here, the highest and lowest values of are selected based on the maximum and minimum cell size along the width of the groove, which are presumed to adequately resolve the local flow gradients. In both cases, the converged mesh variant used for the present analysis is validated against the results of unbounded flow (), based either on experiments or previous simulations.
Figure 3c,d illustrates the variation of and , respectively, with respect to , highlighting the significance of node resolution along the cylinder surface. In both figures, the present results—obtained using the three combinations of node resolutions—are compared with findings from earlier numerical studies conducted at varying and values. Figure 3c reveals that, with respect to the unbounded flow results, the value of is underestimated for and , and it is slightly overestimated for and combinations, whereas the estimated for the combination of and agree well with the referenced unbounded flow data. The above findings indicate an optimal node spacing of for the free-stream-facing section and for the wake-facing section of the cylinder to ensure blockage-independent results. These findings support the previously stated concept of employing variable node spacing in the finite volume method, based on local flow gradients.
Figure 3.
Illustration of mesh validation and convergence using field parameters: (a) coordinates of the vortex core () and (b) wake boundary and surface variables: (c) coefficient of drag () and (d) onset of separation (). In the figures, the literature data are cited using abbrevaitaions: CB1977—Coutanceau and Bouard, 1977 [29], PG2007—Posdziech and Grundmann, 2007 [11], S2009—Sen et al, 2009 [12], R2009—Rajani et al, 2009 [30], H1995—Henderson, 1995 [31], TK1969—Takami and Keller, 1969 [32], and HR1969—Hamielec and Raal, 1969 [33].
2.6. Laminar Flow Solver
In the present study, the test cases are simulated using ANSYS Fluent’s Viscous (laminar) solver, which solves the Navier–Stokes mass (Equation (1)) and momentum conservation (Equation (2)) equations. Furthermore, the solver neglects turbulence entirely, presuming a laminar regime and resulting in a steady flow. For a steady two-dimensional incompressible flow, the governing equations are given by
In the above two equations, denotes the velocity vector with and as its streamwise and normal components, is the local static pressure, and is the dynamic viscosity of air. Here, ∇ denotes the gradient operator, while ∇· represents divergence and ∇2 represents the Laplacian operator. It must be noted that the fluid properties, such as (density) and , are set to standard values estimated at the room temperature of °C: and . To enhance the solver’s convergence stability, ANSYS Fluent® incorporates under relaxation factors [27]. In this context, the nominal values of 0.3 and 0.7 are used for pressure and momentum field, respectively, across all test cases investigated. It is worth mentioning that the resultant mesh (Figure 2b) has an orthogonal quality close to 0.996, which is determined using the “Mesh Report Quality” feature of ANSYS Fluent® solver. This implies that there are no skewed cells in the computational domain. Accordingly, the pressure-velocity coupling in the governing equations is solved without skewness correction, using the Semi-Implicit Method for Pressure-Linked Equations (SIMPLE) scheme. Further, the spatial gradients in the flow field are resolved using “Least Squares Cell-Based” algorithm, while the pressure and momentum variables are solved using “Second Order” and “Third-Order MUSCL” algorithms, respectively. The computations are initialized based on the boundary conditions defined at the Inlet boundary: uniform streamwise velocity (, ) at standard atmospheric pressure (). It is well known that, for a 2D flow, the drag coefficient is unique for a given . In this light, the convergence criterion of 0.001 is set for the force values () rather than monitoring the continuity or momentum residuals. As a result, the computing time to obtain an overall steady flow field is effectively reduced.
3. Results and Discussion
The present numerical study carried out using ANSYS Fluent® software examines the steady separated flow past the grooved and smooth (non-grooved) circular cylinder for the diameter-based Reynolds numbers () of 7.5, 10, 15, 20, 25, and 30. Specifically, the influence of groove geometrical parameters—such as groove depth () and spacing ()—on the wake characteristics is analyzed at each , with a focused analysis on the role of . In this regard, four levels of h (, , , and ) and five variants () are considered along with the baseline across the present values, resulting in a comprehensive set of 250 test cases. Given this, the results are analyzed relative to the baseline at each . It is thought that the principal factors required for detailed examination of the flow characteristics are the pressure at the front () and rear () stagnation points, onset of separation (), and topological characteristics of the wake [5]. The discussion begins with the analysis of the effect of on surface pressure distribution, and associated variables, such as , , , and are examined. Subsequently, the influence of β on the wake field and the representative parameters, such as the length () and the width () of the wake, coordinates () of the wake core, and minimum velocity (), are analyzed, followed by modeling the consistent trends in the surface and field variables with respect to the range of and investigated in the present study. Before concluding the discussion, the parameters that remain unaffected across different groove configurations considered in this study are presented as well.
3.1. Surface Pressure Distribution
Generally, the foremost impact due to change in cylinder profile is realized on the flow tangential to the surface. In this regard, the present section details the alterations in surface pressure distribution induced by the grooved cylinder configuration, particularly the groove spacing . Figure 4 shows the variation of the non-dimensional pressure coefficient () along the grooved cylinder surface, relative to the baseline. Specifically, Figure 4a–c illustrates the distribution for , presenting the results of all groove configurations. It is evident that the fluctuates rapidly along the groove profile. Precisely, for each groove, the descends and recovers sharply along the first half, i.e., between the start and middle of the groove, and vice versa in the next half. This observation recalls the inference from the numerical study of flow past the grooved cylinder, conducted by Zhang and Ko [16]. The authors indicated that the influence of grooves on the flow field is equivalent to imposing a local slip velocity on the cylinder surface rather than the usual no-slip boundary condition. Against this background, it is reasonable to presume that the flow accelerates and then decelerates along the length of the groove. It is worth noting that the fluctuation amplitude is prominently sensitive to the angular position of the groove. Given this, the fluctuation in the figure appears to diminish between , regardless of the groove configuration. Besides, the value for the grooved cylinder agrees closely with the baseline value at each investigated. The intriguing aspect is that the above-mentioned angular range corresponds to the wake partition in the computational domain, where flow separation is anticipated. Similarly, Babu and Mahesh [19] and Afroz and Shariff [24] reported comparable findings in their numerical study of flow past a grooved cylinder. The former authors employed cactus-like grooves and simulated the flow in the range of , whereas, the latter authors examined three groove shapes—V, U, and rectangular—each with a unit aspect ratio in the range . In both works, the authors observed that fluctuations diminished beyond (or ) from the front stagnation point, which they attributed to the weak momentum of flow within grooves exposed to an adverse pressure gradient caused by separated flow. Furthermore, the present finding agrees well with the observations of Zhang and Ko [16], which suggests that the slip velocity in the grooved segment is higher for the groove location closer to the front stagnation point and decreases with increasing until the base, measured clockwise.
Figure 4.
Illustration of distribution over smooth (non-grooved) and grooved circular cylinders. Effect of groove spacing at (a) , (b) , and (c) . (d) envelopes for all investigated in the present study.
It is worth noting that the groove aspect-ratio () plays a nominal role in altering the peak values. This affirmation is arrived at by estimating the average of individual peaks for each groove. In the figure, the top and bottom dashed lines—with respect to the baseline (thick solid line)—indicates the average of lower and upper peaks, respectively. Evidently, the envelopes are in proximity to the local extrema of along each groove. Moreover, it is worth noting that the envelopes are less likely to be altered by . For convenience in discussion, the difference between the lower and upper envelopes is denoted by . The figure reveals that, irrespective of groove depth (shallow or deep) or spacing (narrow or wide), increases gradually from the stagnation point, reaches its maximum amplitude, (), between , and then decreases toward the cylinder base. This observation recalls a significant finding from the study conducted by Kimura and Tsutahara [14] on the flow at , past a cylinder with circular grooves configured at varying depths. The authors carried out flow visualization and numerical simulation and demonstrated that the groove, regardless of its depth, is effective when placed near from the front stagnation point. Furthermore, the efficacy was attributed to the fully developed closed recirculating flows inside the grooves. The above discussion indicates two noteworthy aspects: 1. Higher fluctuation, implying well-developed vortex flow, occurs in case of cavity flow within the groove, and 2. The effective position of the rectangular groove is shifted upstream from [14] to due to the interaction of neighboring grooves.
The concatenation of the envelopes of peaks, estimated for other in the present range of interest, are shown in Figure 4d. The value at and —which corresponds to the coefficient of the stagnation () and the base () pressure—depends distinctly on . The former decreases with , whereas the latter exhibits the opposite behavior. Also, the figure reveals that the envelope is more influenced by , compared to the cylinder configuration. It is worth noting that the envelopes and the overall shrink with increasing , regardless of the groove configurations. Besides, the figure reveals that the expanding-contracting behavior in envelopes with respect to is consistent across all groove configurations and investigated in this study. In this perspective, it is reasonable to presume that any variation in the flow characteristics due to the presence of grooves is likely attributed to the recurrent fluctuations. In other words, lower results in a higher number of grooves—whether shallow or deep—that are spaced closer to each other. As a result, frequent fluctuations along the surface of the grooved cylinder may significantly perturb the flow, thereby influencing the field parameters more strongly than in cylinders grooved at higher . Notably, this notion aligns with the present objective of examining the impact of on the characteristics of the steady separated flow. Notably, the global and —estimated based on the envelope occurs for the lowest in the present study, . Moreover, the variation of the -extrema with is distinct for the lower Re range: , compared to that of the higher range, i.e., . Hence in the forthcoming sections, results are compared for , , , and , where the flow fields and associated variables tend to exhibit significant variations.
3.2. Effect of β on Surface Variables
Because of altering the cylinder geometry, the impact on the variables such as the stagnation pressure (), base pressure (), separation angle (), and drag () estimated along the cylinder surface is pronounced. It must be noted that the envelopes for the grooved cases (Figure 4) are constructed by estimating the average of the peaks. The beginning and end of the pressure envelopes reveal the variation in and , respectively, with respect to . From a general perspective, it indicates the overall change in the flow field. Yet, a closer examination of the effect of groove configuration ( and ) on , , , and remains essential to the present objective. In this context, the following sections detail the variations in the above-mentioned variables due to and , with an emphasis on the latter.
3.2.1. Modifications in Front () and Rear () Stagnation Pressures
Figure 5a–h depicts the effect of on and , respectively, relative to the baseline value. For all the and studied herein, it is observed that increases considerably when more grooves are closely placed, approaching the baseline value as the becomes larger. This observation reinforces the idea that persistent pressure variations along the surface of the cylinder tend to induce proportional disturbances in the flow field, Figure 4. Relatively, increases by when the grooves are placed closer (), while, for , it is higher than the baseline. It is worth noting that, at these extremum, the collapses to a single value. The overlap is also observed for the combinations of shallow () and square () and deep () and deeper () groove configurations at . On the contrary, grooves located at result in distinct values of for each groove configuration. While for , moderate to notable variations in are observed with minor overlaps. Here, due to deep and deeper grooves tend to overlap, and the discrepancy between shallow and square groove is distinct. It should be emphasized that, for , the impact of shallow groove on is pronounced than the other configurations, whereas, at , the opposite behavior is observed. The extreme groove configurations, i.e., and , perform almost similarly at . Furthermore, the sensitivity of to is pronounced until , compared to the trend existing beyond this spacing. The above results highlight two noteworthy aspects: shallow grooves outperform the other configurations under closer spacing (), and it is likely that tends to be critical spacing for the evolution of flow field along the cylinder, regardless of the groove configuration. The corollary being that the dependency of on is non-monotonic and is primarily governed by their spacing along the cylinder surface. This statement emphasizes the significance of over the of the grooves. On aggregate, it Is curious to notice that the above findings of remain consistent across the present range of , regardless of the grooved cylinder configuration.
Figure 5.
Illustration of the effect of on front () and rear () stagnation pressures. (a,e): ; (b,f): ; (c,g): ; (d,h): .
Figure 5e–h depicts the effect of on the variation of , where it is evident that, for the simulated cases of and , the magnitude of for the grooved cases is consistently lower than the baseline value. In addition, a shift in trend is observed beyond , particularly for . Given this, the -trend in the lower range, , is ascending with , whereas it is vice versa for the higher range, . Therefore, unlike a consistent trend observed for , the shift in -trend results in inconsistency across the range of studied. Besides, significantly deviates from the base value with increasing , which is just the opposite of what is observed with (Figure 4). The trend shift is associated with a simultaneous increase and decrease in with for the groove spacing of and , respectively. As a result, value for closely spaced grooves overshadows those observed for wider groove spacing. However, the following features remain consistent across the range of investigated: 1. For closely spaced grooves (), induced by the shallow groove () is relatively higher compared to other configurations; 2. Widely spaced grooves () yield similar , converging to a single value across all settings; and 3. At the intermediate spacing, and , the deep and deeper groove configuration yields identical . It is worth noting that, for , the rate of increase in is pronounced until , compared to the nominal variation beyond °. However, there is a rapid decrease in for shallow groove at and recovers at . Beyond , the rate of change in is relatively nominal across all . Though the trend is consistent for all examined, the reason for this sharp descend is not obvious. In contrast, the -trend for the deeper groove configuration () is relatively more stable at the lowest . The observation is consistent with the findings pertinent to the steady flows in rectangular cavities, observed by Pan and Acrivos [26], using numerical simulation and visualization techniques. It was demonstrated that the flow behavior in a deeper cavity is comparable to the steady circulating wake formed downstream to the cylinder, where the viscous and inertial forces remain in equilibrium. It follows that the deeper cavity in the present study likely stabilizes the flow by minimizing the imbalance between the viscous and inertial forces during each fluctuation observed along a groove. As mentioned earlier, for increases at ; hence, the difference between the consequent values of decreases, compared to that observed at . At , for continues to rise, with the shallow groove producing the overall maximum, followed by a distinctly sharper decline. While for the other configurations, the increase in values for closely spaced grooves result in a reduced discrepancy between the values at and . On aggregate, the overall variation in across the range of diminishes with increasing .
3.2.2. Coefficient of Drag
In fact, the drag coefficient () decreases with an increase in , Figure 3. It is known that grooves are intended to further reduce the drag force, thereby improving the aerodynamics of bluff bodies even at lower [14,17,20,25]. Figure 6 illustrates the effect of on the coefficient of total drag (), along with the pressure () and viscous-drag () components. In line with the established perspective, the figure demonstrates that, despite the grooves’ or settings, the for grooved cylinder is lower than the baseline (or non-grooved case) value at each . Specifically, is least for grooves with placed at spacing. It implies that the efficiency of drag reduction increases with the groove depth, while it is significantly higher when the grooves are placed closely along the cylinder surface. Moreover, the figure indicates that, with increasing , the value of for the grooved cylinder approaches the baseline value, regardless of setting. Given this, for all values investigated, the difference in across varying settings are relatively small at compared to other groove spacings. Though the above findings support the notion of flow control using deeper grooves, mentioned in the preceding section, they emphasize the effect of over . In other words, the effect of groove counts is noticed to be significant than the groove depth itself. Similarly, Yamagashi and Oki [18], using numerical simulation and oil flow visualization, demonstrated that the mean at lower for a cylinder with 32 grooves is significantly lower than that obtained for 26 and 20 grooves. Also, the recent numerical study on grooved cylinders conducted by Afroz and Shariff [24] had associated the cause for drag reduction with the presence of local recirculation bubble within the groove and correlated it as aiding partial slip of free-stream above the groove. It is worth mentioning that the findings of Zhang and Ko [16] and Afroz and Shariff [24] are also comparable with respect to the notion of slip velocity for grooved cylinders. It follows that a lower accommodates more grooves, which proportionally increases local bubble formation and slip velocities, thereby reducing drag. Furthermore, these observations reinforce the concept of proportional modification of the flow field due to recurrent fluctuations at lower (see Figure 4). Unlike the inconsistent trends observed in the surface variables and with respect to either or (Figure 5), the variation of across the cylinder configurations is monotonic for all values investigated. In other words, at each , decreases with increasing , regardless of , while it gradually increases with increasing , despite varying h/w configurations. It must be noted that, although the contribution of in the total drag is less than , the trends in and are comparable, despite an increase in or changes in the cylinder profile studied herein. In contrast, increases with an increase in and decreases with an increase in , which is exactly opposite to the trends of and . But for the shallow groove, remains almost constant with respect to , exhibiting a plateau-like trend. Apart from the flat trend seen in the figure for , the following aspects in the -trend are comparable with those observed for and (Figure 5). At , , and , for square, deep, and deeper grooves is similar with significant overlaps, while, at and , is distinct for each showing minor overlaps. Although non-monotonous with respect to , the above trends in against varying is consistent across all in the present range of interest. In addition, the concurrent decrease in and the area of envelope (Figure 3) with increasing highlights the closer association between the pressure field and the pressure component of the total drag.
Figure 6.
Effect of on the total drag coefficient () and its pressure () and viscous () components. (a,e,i): ; (b,f,j): ; (c,g,k): ; (d,h,l): .
To acquire a quantitative perspective on the above observations, the variations in with respect to and are estimated relative to the baseline value, denoted as . The value of is estimated using the relation, , where the subscripts and denote the value of for grooved and non-grooved (baseline) cases, respectively. In Table 2, the values of are given for all investigated in the present study, where each quantity denotes the percentage reduction in due to the grooved cylinder, compared to the baseline value at respective . From the data presented in Table 2, it becomes clear that the most efficient drag reduction occurs with a deeper groove () placed closer at , particularly when the is at its lowest. In this case, is nearly lesser than the corresponding value. Moreover, the is higher for a given groove depth when closely placed (), which decreases with increasing . At this point of discussion, it is worth comparing the present findings with that obtained experimentally by Zhou et al. [22] in the range of for a circular cylinder having grooved and dimpled surfaces. Relative to the baseline value, the authors observed a largest drag reduction of using square grooves at , compared to reduction at , while that for the dimpled cylinder, it ranged between 10–30%. It follows that the drag reduction efficiency increases notably by optimizing the groove spacing, even at much lower .
In addition to the above observations, the tabulated data reveal an intriguing aspect: for a specific setting, the reduction efficiencies of shallow () and square () grooved cylinders at lower ( or ) and those of the deep () and deeper () configurations at moderately higher are comparable. For instance, for the groove at is similarly efficient as that for groove at , with both configurations placed at . Similarly, the groove with at performs akin to the groove at . The observation is consistent across all values tested herein, thereby agreeing with the contribution of groove depth in flow-controlling applications [26]. Thus, a grooved cylinder configured at lower is significantly effective in reducing the drag regardless of or merely operating at the lowest . For example, at , of the groove at is approximately twice as effective as that at , indicating a improvement in efficiency. This trend persists across successive pairs within the studied range, whereas the for the same configuration at is nearly efficient than that observed at . It follows that plays a vital role compared to the groove in terms of drag reduction and flow control.
3.2.3. Onset of Separation
Research indicates that a laminar boundary layer exposed to a strong adverse pressure gradient may separate from the surface, forming either a separated shear layer or wake flow depending on the surface geometry. Figure 7 shows the snapshots of steady separated flow past non-grooved and grooved cylinders, where the portion of the cylinder between is shown. In the figure, the flow field in the proximity of the onset of separation () is shown using streamlines (blue lines) and contours of vorticity (pink colored lines). Figure 7a,f,k shows the flow field past the non-grooved cylinder at , , and , respectively. Each figure reveals that the vorticity and the stream function tend to be zero adjacent to the separation point. This observation is consistent with the criteria adopted in the earlier numerical studies to identify [12]. Similarly, is estimated for the grooved cylinders by identifying the regions of vanishing vorticity/streamfunction in the proximity of the respective baseline . However, it is worth mentioning that the above criteria tend to yield more than one for grooved cylinders configured for , especially at and .
Figure 7.
Illustration of streamlines (blue lines) and vorticity field (red lines) in the vicinity of the onset of separation, revealing secondary separation with bubble, and trapped vortex separation. The subfigures (ae), (fj), and (ko) depict the separation characteristics for , , and , respectively. The cylinder configuration ( and ) and onset of separation () are specified in the corresponding subfigure.
Figure 7b,g,l each corresponds to the field at , , and , illustrating the separated flow past the grooved cylinder configured at . It can be noticed in the figure that this groove spacing places the grooves very near the baseline , especially at and , which is and , respectively. Given this, the corresponding opening and closing angles of the groove located near the former are and , while for the latter , they are and . Furthermore, the figure reveals locally separated-reattaching streamline—reminiscent of the separation bubble—extending between the edges of the groove located near respective . Following Kimura and Tsutahara [14], and for the discussion, the groove edges facing upstream and downstream are denoted as its leading and trailing edges, respectively. These authors observed that when a fully developed recirculating flow—also known as the “cavity flow”—occurs within the groove, then the streamline tends to separate at the leading edge and reattaches by the trailing edge of the groove, appearing as a bubble-like flow over the groove. Comparably, in the present study, this phenomenon exists over deeper groove () as well for (Figure 7c) and (Figure 7m), particularly at . This observation is consistent with the observations of Pan and Acrivos [26], which indicated that the cavity flow occurs in a sufficiently deeper cavity. It follows that the inconsistency of the criteria in detecting multiple is likely associated with the secondary separation occurring just upstream of , whereas, in the case of , the separation point is located distinctly away from the upstream groove and moderately away from the downstream groove. This observation is valid for other cases of investigated in this study, i.e., , , and , where the criteria yield a single . Similarly, when the grooves are placed at , the local reattachment is not observed, despite varying groove depths, at (Figure 7d,e) or (Figure 7n,o). However, an intriguing phenomenon is noticed at for the groove spacing of . Figure 7i,j shows the near field of separated flow at around grooved cylinders, each having a groove depth of and , respectively, where both configurations are placed at . The figures reveal that, regardless of the groove depth, the separation streamline () originates exactly over a groove, whose midpoint coincides with the respective . Furthermore, the isoline of appears to be resting on a vortex structure trapped on top of the groove. This phenomenon also occurs at for the grooved cylinder configured with a depth of and placed at , Figure 7o. Although in the case of a shallow groove, (Figure 7n), the flow appears to separate on top of the groove, is notably shifted upstream of the baseline value, occurring at the edge of the groove. It is likely due to the early ; the trapped vortex is absent in this case.
3.3. Effect of β on Wake Characteristics
Earlier studies on grooved cylinders had demonstrated that the grooves likely shorten the streamwise extent of the wake and shrink the groove width, resulting in effective drag reduction [11,13,18]. Figure 8 illustrates the influence of on the length () and width () of the wake. It should be noted that the former is determined based on the zero-crossing points of the streamwise velocity () distribution along the centerline, starting from the cylinder base [12]. The latter is estimated from the ordinate maximum for the isoline of zero stream function (), which implies the vertical extents of the steady wake relative to the centerline. Figure 8a–d reveals that, for all and investigated herein, the steady wake gets shorter when the grooves are located closer to each other, despite the groove’s depth. Given this, is at its lowest for and approaches the baseline value at a larger . For the lowest studied (), it is observed that the growth rate of is significantly lower beyond , compared to the distinct growth below this groove spacing.
Figure 8.
Illustration of the variation of wake-length () and width () with respect to the groove spacing . (a,b): ; (c,d): ; (e,f): ; and (g,h): .
Particularly, for deeper grooves (), remains almost constant past . In this scenario, the value of for deeply grooved cylinder is unlikely to reach the baseline value, even at the highest possible , while for shallow and square grooves, fluctuates alternatively with increasing . It is worth noting that this trend is consistent across the investigated herein. It implies that increasing groove depth beyond its width (i.e., for cases where ) and configured at wider spacing tends to significantly stabilize the flow field, compared to shallow or square grooves. It is curious to notice that, for , the grooved cylinder tends to yield wakes longer than the non-grooved or baseline case, specifically when the grooves are spaced beyond . This observation fits well for deeper grooves (), compared to deep (), while for the other groove configurations (), L exceeds the baseline value beyond . However, the overall trend in establishes at and remains consistent thereon. It must be noted that the aggregate trends of and that of or (Figure 6) are very well comparable with respect to . Thus, and correlate directly, as both variables increase with increasing . However, with respect to the groove aspect-ratio h/w, the variation of exhibits a nonlinear and non-monotonic relationship, like and . The figures reveal identical wake lengths consistently for a pair of configurations at specific . Given this, the wake lengths for shallow () and square () grooves, as well as for deep () and deeper () grooves, are identical at successive values within the range: . The value of for all conditions overlap for . In some cases, the value for grooved cases tend to approach the baseline value at higher . Though this trend is consistent across the studied herein, the root cause of the similar produced by a specific pair of remains unclear.
Figure 8e–h illustrates the changes in the wake-width with respect to varying and . In Figure 8e, which presents the results for the lowest (), a consistent fluctuation in relative to the baseline value is observed, regardless of the configuration. As a result, the wake produced by the grooved cylinder with groove spacings of and exhibits increased width, with the latter being significantly wider than the non-grooved case, whereas the opposite trend is observed for groove spacings of and . At , the values of are lower than the baseline for all groove configurations, yet converge to a single value. For (Figure 8f) and (Figure 8g), the trend in considerably differs from the variation pattern observed for . A noteworthy aspect is that the -trend at evolves fairly like the -trend noticed at the corresponding . From this onward, both and exhibit comparable trends, wherein the grooved cylinder appears to confine the wake topology to levels well below the baseline case. Remarkably, the growth pattern of in the range, and of for tends to shift notably at . It implies that, in addition to the flow development along the cylinder surface, this groove spacing is likely a critical limit in altering the wake characteristics. On comparing the trends of against those of —which remains consistent with respect to —it follows that the topology of the steady wake is closely associated with the changes in the upstream pressure field induced by groove spacing. Furthermore, the above findings appear to reflect the influence of on the pressure distribution along the cylinder surface, Figure 3. In the earlier section, it is discussed that the variations in the field parameters may be linked to the recurring fluctuations. It is worth remarking that the results of comply with the notion of fluctuations. In other words, the wake extent in the streamwise and normal direction is significantly controlled by the groove count or, equivalently, the spacing between each groove, across the range of investigated herein.
3.3.1. Vortex Center
Figure 9 shows the influence of grooved cylinder configurations on the coordinates of the vortex core, relative to the baseline value. Particularly, the figures in the left column illustrate the variation in the abscissa of the vortex center, denoted as , while those in the right column show the modifications in the corresponding ordinate, denoted as . In the present study, and are determined from the intersection of the isolines of and (Figure 1). Figure 9 evinces that, for most of the range investigated, the grooved cylinder with closely spaced grooves tends to drag the vortex core toward the base of the cylinder. With increasing , the vortex core moves away from the cylinder base, approaching the core location observed for the baseline. It is worth mentioning that, at the lowest , the trends in (Figure 9a) and (Figure 9b) remain radically different from those observed at other considered in the present study. Particularly, the shift in and exhibits an opposing trend, with respect to . Taking this into account, the abscissa ξ remains farther from the cylinder for closely spaced grooves, and it shifts toward the cylinder base for increasing until . Beyond this groove spacing, moves off the rear stagnation point (or base) of the cylinder, approaching the baseline value. In contrast, the ordinate moves away from the centerline with increasing until , thereby exceeding the baseline location. Thereon, for grooved cases decreases and becomes equivalent to the baseline value at . Intriguingly, the ordinate at each remains nearly identical regardless of the groove depth, while for the remaining range of , between , both and vary congruently with respect to . Given this, remains closer to the base of the cylinder and moves farther with increasing . Similarly, rises significantly with varying , exceeding the baseline value beyond . In both cases, nominal to moderate fluctuation is observed at each for different groove depths. Furthermore, notable shift in the growth rate of and is observed at . This observation is consistent across the range of investigated in this study and supports the notion that likely represents a critical spacing that significantly alters the flow field. At and beyond, the trend in appears to be coherent and very well comparable to that observed for wake length () at the corresponding (Figure 8). Although the evolution of with respect to is comparable to that of , the correspondence becomes more apparent at . Notably, the trends in and display a remarkable degree of agreement across both and , underscoring a strong correlation between wake length and vortex core position. Besides, this interesting consistency reinforces the critical role of in controlling the wake dynamics.
Figure 9.
Effect of on the abscissa () and ordinate () of the vortex center. (a,b): ; (c,d): ; (e,f): ; and (g,h): .
3.3.2. Minimum Velocity ()
It is thought that the centerline -profile for stationary wake attains a minimum () at a particular distance downstream the rear end of cylinder, which is dependent on [8,9]. Besides, earlier investigations incorporating single or multiple grooves on circular cylinder indicated modifications in . In the present study, the effect of groove spacing on is emphasized over and groove depth (). Figure 10 shows the variation in with respect to , relative to the baseline value. As noticed from the figure, the trends in are consistent across , except for the case of . The inconsistent variation in u_min is comparable to that of abscissa of the vortex core observed at the lowest (Figure 9a). However, unlike , which consistently remains lower than the baseline value, for the grooved cases fluctuates relative to the baseline value. The nonlinear and non-monotonic patterns of and with respect to both and indicates significantly perturbed wake flow at the lowest . Intriguingly, the trend in establishes beyond this , where the decreases on aggregate with increasing .
Figure 10.
Illustration of the effect of on the variation of the minimum of the streamwise velocity , measured along the cylinder centerline. (a): ; (b): ; (c): ; and (d): .
The only difference is that for grooved cases at are consistently lower than the baseline value, whereas, at , for a grooved cylinder with closely spaced grooves until remains higher than the baseline value, regardless of groove aspect-ratio . In case of the grooves being spaced beyond , descends below the baseline value. For groove configurations having and , the trend in is identical for . The values of for deep () and deeper groove () merge beyond . Eventually, the for all groove depths investigated herein converges to a single value at .
3.4. Modeling the Aggregate Effect of β on Non-Dimensional Surface and Field Variables
The findings of the present study indicate that, despite varying groove aspect-ratios , the modifications in surface and field variables for grooved cylinders are consistently influenced by the groove spacing . This inference is valid across the range of investigated in the present study, especially for variables such as , , and . While the trends in and are consistent and predictable with increasing for , they are not evident at . It is worth noting that these variables are aligned in the streamwise direction. To gain further insights consistent with the objective of the study, this section attempts modeling the aggregate effect of β on the above-mentioned variables. Notably, the aggregate trends of the first three variables—, , and —are precisely modeled using a power-law equation of the form . However, the variations of the field variables and with respect to are better represented by a simplified power-law equation of the form , with . Here, denotes the modeled variable, and are model constants, and is the exponent that defines the relationship between and . In most cases, the value of is closely associated with the asymptotic value of the variable , which, in the present study, may be the baseline value at the respective . It must be noted that in this context represents the average of the respective variable across different , estimated at each . By doing so, it is viable for the model equation to isolate and evaluate the specific contribution of groove spacing. Besides, the averaging process excludes the non-monotonic effect of observed in the trends of each variable. Hence, and , along with the exponent , are treated as functions of . It is worth mentioning that the surface variables and correlate strongly with , resulting in a value of at each , across the investigated . For , the above equation captures its variation with a confidence level () ranging from to , depending on . The reduction in at the lowest () is attributed to the significant decrease in the growth rate of beyond . Similarly, the models for and demonstrate between 0.87 and 0.95, increasing progressively with rising . At this point of discussion, it is key to remind that these equations significantly focus on how the variables change with at different rather than on their exact values. Figure 11 illustrates the dependence of the constants and exponent in the power-law models as a function of .
Figure 11.
Variation of the modeling parameters , , and in the power-law modeling equations as a function of . (a–c): ; (d–f): ; (g–i): (j,k): ; and (l,m): .
3.4.1. Modeling - Trend
The variation in the values of , , and used to model the trend in front stagnation pressure coefficient are shown as a function of , respectively, in Figure 11a–c. From the figure, it is evident that the factors involved in the model equation progressively descend with , implying a monotonic and convex descent in with increasing . Particularly, the negative values of exponent at each reinforce the inverse relationship between and , i.e., . Since the value of is positive across the range of investigated, the term dominates at smaller values of . It implies that the rate of change in is significant for closely spaced grooves, compared to wide spacing. At higher , the above term vanishes; thereby, asymptotically approaches at the respective . The decaying trend in indicates an overall downward shift in - trend with increasing . On aggregate, the flow field modifications induced by the grooved cylinder having closely spaced grooves are amplified for the lowest investigated herein. These observations are in very good agreement with the findings of in Figure 4 and Figure 5, thereby emphasizing the accuracy of the power-law equation in modeling the effect of on .
3.4.2. Modeling - Trend
Figure 11d–f corresponds to the dependency of the elements of power-law equation used to model the trend in with respect to . The figure evinces that both and are less than zero across the considered herein, resulting in an inverse relation, i.e., , and negative scaling factor, . It indicates a rise in with increasing , approaching asymptotically toward at higher and significantly downscaling from the baseline value at lower . Furthermore, for lower values of the negative term, is prominent at lowest , implying a large upward shift in , compared to growth rate of for higher . As increases, becomes less negative, and becomes more negative, leading to the diminishing of the term, . Consequently, the growth rate of becomes insignificant. In this light, it is presumed that acts as a sensitivity amplifier for . In other words, closely spaced grooves along the cylinder surface significantly reduce the when the is at its lowest permissible limit of steady separated flow. Overall, the descending trend of asymptote indicates that the net effect of employing a grooved cylinder for most practical ranges of is to bring down the . These findings comply very well with the observations of based on Figure 6 and Table 4.
Table 4.
Variation in induced by a grooved cylinder, relative to the baseline.
3.4.3. Modeling ()- Trend
The functional illustration of , , and , with respect to , as shown in Figure 11g–i, corresponds to the parameters involved in modeling the change in non-dimensional wake length . The trends in (Figure 11g) and (Figure 11h), with respect to , reveal a noteworthy aspect. Unlike the consistently negative or positive values of A and n observed in the models of and , the present case exhibits zero crossing points. Particularly, the values of and change from positive to negative or vice versa between and . It implies that the effect of vanishes for a specific , where or , and the value of is equivalent to the corresponding asymptote. In Figure 8, it is observed that the overall trend in stabilizes between and and is comparable between consequent thereon. Furthermore, and vary significantly until , compared to the descending rate observed thereon. This trend is likely associated with the significant growth rate in for lower until , as seen across the lower range in this study (Figure 8). The asymptote rises almost linearly with , agreeing with the overall ascending trend in with increasing , as observed earlier in Figure 8.
3.4.4. Modeling ()- Trend
Figure 11j,k depicts the magnitude and dependency of and with respect to , which are used to model the aggregate trend of versus across range. In this case, across the model’s range, which signifies that the overall upward shift in ()- trend is negligible compared to the increase in a with respect to at a given . The figures show that both and are positive; however, increases while decreases as increases. The positive value of indicates the net increase in with respect to , while at each suggests a growing trend in with increasing . Furthermore, descends significantly in the lower range until , compared to the decay rate observed beyond this . It is worth noting that, across lower range of , is smaller, and is larger, which is associated with the steep rise in induced by closely spaced grooves, while smaller and larger at higher indicates moderate net growth rate in . It follows that, to contain the value of a with increasing , the groove spacing must be minimum. These findings warrant that the critical shift toward the lower limit as increases. This inference reinforces the notion of being a critical spacing, as observed in the earlier sections.
3.4.5. Modeling )- Trend
The dependency of the parameters and in the equation, , is shown in Figure 11l,m, respectively. Similar to the preceding model, the model for is valid for . Moreover, indicates that has a moderate influence on compared to the stronger effect of . The figure shows that both and decrease with , with the former being negative, and the latter is positive across the range of investigated. Here, the negative scaling factor suggests a net decrease in with respect to both increasing and . Besides, the magnitude of in separated flows is negative for the practical range of , thereby resulting in . Therefore, the positive in this case must not be interpreted as a proportional relationship, i.e., . Rather, the decaying positive value of n represents the rate of change or sensitivity of with respect to changes in at the corresponding . It is worth reminding that decreases significantly with for given within the range of , Figure 10. Hence, the trend in , as observed from Figure 11m, reveals that the rate of decrease in with respect to is pronounced for lower , compared to that for higher . Given this, it is evident that is less negative and is larger for , resulting in a dominant magnitude of . It suggests a steep drop in with in the above range of , whereas for , the rate of change in with is relatively small. It follows that, in order to maintain a constant for increasing , the groove spacing is required to be smaller such that the product does not overshoot at higher .
3.5. Field Parameters Unaffected by the Cylinder Configuration
Apart from the aforementioned discussions on the effect of and on surface and field variables, this section highlights an intriguing observation: the streamwise locations of maximum width () and minimum velocity () remain unaffected by the cylinder configurations. Figure 12a,b illustrates the variation of and , respectively, with increasing . It is important to note that is measured from the center of the cylinder, whereas is referenced from its rear edge. This shift in reference points is due to the relative positions of these locations. At the lowest Reynolds number investigated (), lies upstream of the cylinder’s rear end, which would result in a negative value if measured from the rear edge. To avoid misinterpretation, is instead measured from the cylinder’s center. However, as increases, moves downstream, eventually crossing the cylinder’s diametrical point. Since the data for baseline and grooved cylinder configurations are identical, few representative cases of the latter, such as at , at , at , and at , are shown in the figure. The arbitrary choice of grooved cases has no particular significance, but to avoid clogging of data points and ease interpreting the figure. Besides, for a given , the data in the figure distinctly reveals that and are the same across different combinations of and configurations. It is evident from the figure that and increase in a linear trend with respect to . Furthermore, a noteworthy aspect is that the numerical data agrees very well with the experimental results of unbounded flow (), obtained by Coutanceau and Bouard [29].
Figure 12.
Variations in the streamwise locations of the (a) maximum wake width () and (b) velocity minimum (), illustrating the independence of these variables with respect to the cylinder configuration In the above figures, the literature data are cited using abbreviations: CB1977—Coutanceau and Bouard [29], 1977, NK1973—Nieuwstadt and Keller [10].
4. Conclusions
This study numerically examines steady separated flow past grooved and plain cylinders (), focusing on groove depth () and spacing (). A total of 250 cases cover four levels () and five variants (). Along each groove, the surface pressure () fluctuates between a local and . The overall is dependent on ; however, the surface variables and the wake field parameters—linked with the change in pressure field—are considerably influenced by , compared to varying groove depth, . Given this, the closely spaced grooves () significantly enhance the front stagnation pressure () and reduce the rear (or base) counterpart, . The drag force () and its viscous component () are at their lowest for , and vice versa in case of the pressure component (), eventually approaching the baseline value at higher . When a groove with cavity flow is near the onset of separation (), a bubble-like reattachment along the groove tends to delay the flow separation. If separation starts mid-groove, anchors to a trapped vortex. Regardless of the groove depth, these findings emphasize the significant role of optimal in positioning grooves for effective flow control. The consequences of the modified pressure field circumventing the cylinder surface are also manifested in the characteristics of the downstream wake. Thus, the closely spaced grooves contain the overall topology of the stationary and symmetric wake, with its core location dragged toward to the cylinder base. As a result, the centerline momentum is considerably reduced. Mathematical models based on the power-law equation of the form , obtained across all investigated in the present study, fairly define the consistent trends in , , , , and with respect to . Although the trend in with respect to remains consistent across all examined, the underlying reason for the similar values produced by specific pairs of ratios remain unclear. Likewise, the occurrence of an unestablished wake field in the lowest range of Reynolds numbers investigated ()—as indicated by the field parameters , , , and could not be rationalized. Apart from these variables influenced by , it is found that the streamwise locations of the maximum wake width and minimum velocity remain independent of the cylinder geometry.
On aggregate, it is worth mentioning that the results presented in this study are fairly independent of the domain blockage and consistently indicate that a grooved cylinder can become efficient in terms of drag reduction and flow control when the grooves are closely spaced along the cylinder surface. In this regard, a groove spacing of appears critical—regardless of the groove aspect ratio —as the sensitivity of the flow variables decreases considerably beyond this spacing. The present work might serve as a basic reference for future works investigating the effect of on flow instability, turbulent transition, and unsteady vortex dynamics, with particular emphasis on the critical spacing .
Author Contributions
Conceptualization, G.K.T. and R.K.V.; methodology, G.K.T. and U.D.; software, G.K.T. and A.M.; validation, G.K.T. and R.K.V.; formal analysis, G.K.T. and R.K.V.; investigation, G.K.T. and R.K.V.; resources, G.K.T. and J.E.V.; data curation, G.K.T. and U.D.; writing—original draft preparation, G.K.T.; writing—review and editing, U.D., A.M. and J.E.V.; visualization, G.K.T. and U.D.; supervision, R.K.V. and J.E.V.; funding acquisition, J.E.V. All authors have read and agreed to the published version of the manuscript.
Funding
This research received no external funding.
Data Availability Statement
The original contributions presented in this study are included in the article. Further inquiries can be directed to the corresponding author.
Acknowledgments
A part of the computations was performed on the Aziz Supercomputer at King Abdulaziz University’s High-Performance Computing Center (http://hpc.kau.edu.sa/ accessed on 4 September 2025). The authors acknowledge the computer time and technical support provided by the center.
Conflicts of Interest
The authors declare no conflicts of interest.
Abbreviations
The following abbreviations are used in this manuscript:
| const | Constant |
| CFD | Computational fluid dynamics |
| Exp. | Experiment |
| Vis. | Visualization |
| HWA | Hot-wire anemometry |
| PIV | Particle image velocimetry |
| sep | Separation |
| min | Minimum of a variable |
| max | Maximum of a variable |
| rel | Relative change |
| G | Grooved cylinder |
| NG | Non-grooved cylinder |
References
- Derakhshandeh, J.F.; Alam, M.M. A review of bluff body wakes. Ocean Eng. 2019, 182, 475–488. [Google Scholar] [CrossRef] [Scilit]
- Coutanceau, M.; Defaye, J.R. Circular cylinder wake configurations: A flow visualization survey. Appl. Mech. Rev. 1991, 44, 255–305. [Google Scholar] [CrossRef] [Scilit]
- Williamson, C.H. Vortex Dynamics in the Cylinder Wake. Annu. Rev. Fluid Mech. 1996, 28, 477–539. [Google Scholar] [CrossRef]
- Taneda, S. Experimental investigation of the wake behind a sphere at low Reynolds numbers. J. Phys. Soc. Jpn. 1956, 11, 1104–1108. [Google Scholar] [CrossRef] [Scilit]
- Lekkala, M.R.; Latheef, M.; Jung, J.H.; Coraddu, A.; Zhu, H.; Srinil, N.; Lee, B.H.; Kim, D.K. Recent advances in understanding the flow over bluff bodies with different geometries at moderate Reynolds numbers. Ocean Eng. 2022, 261, 111611. [Google Scholar] [CrossRef] [Scilit]
- Elsayed, A.M.; Farghaly, M.B. Theoretical and numerical analysis of vortex bladeless wind turbines. Wind. Eng. 2022, 46, 1408–1426. [Google Scholar] [CrossRef] [Scilit]
- Devarajan, K.; Chen, L. Inerter-enhanced nonlinear energy sink reducing vortex-induced vibrations of circular cylinders. Int. J. Dyn. Control 2025, 13, 242. [Google Scholar] [CrossRef] [Scilit]
- Devarajan, K.; Qian, F.; Zuo, L. Suppression mechanism of vortex-induced vibrations using non-linear energy sink with inerter based mechanical networks. Chaos Solitons Fractals 2025, 201, 117246. [Google Scholar] [CrossRef] [Scilit]
- Maity, S.; Santhosh, B.; Balaram, B.; Awrejcewicz, J. Suppression of vortex-induced vibrations using bistable nonlinear energy sink. Commun. Nonlinear Sci. Numer. Simul. 2025, 150, 108952. [Google Scholar] [CrossRef] [Scilit]
- Nieuwstadt, F.; Keller, H.B. Viscous flow past circular cylinders. Comput. Fluids 1973, 1, 59–71. [Google Scholar] [CrossRef] [Scilit]
- Posdziech, O.; Grundmann, R. A systematic approach to the numerical calculation of fundamental quantities of the two-dimensional flow over a circular cylinder. J. Fluids Struct. 2007, 23, 479–499. [Google Scholar] [CrossRef] [Scilit]
- Sen, S.; Mittal, S.; Biswas, G. Steady separated flow past a circular cylinder at low Reynolds numbers. J. Fluid Mech. 2009, 620, 89–119. [Google Scholar] [CrossRef] [Scilit]
- Kumar, D.; Sourav, K.; Sen, S.; Yadav, P.K. Steady separation of flow from an inclined square cylinder with sharp and rounded base. Comput. Fluids 2018, 171, 29–40. [Google Scholar] [CrossRef] [Scilit]
- Kimura, T.; Tsutahara, M. Fluid dynamic effects of grooves on circular cylinder surface. AIAA J. 1991, 29, 2062–2068. [Google Scholar] [CrossRef] [Scilit]
- Leung, Y.C.; Ko, N.W.M.; Tang, K.M. Flow Past Circular Cylinder with Different Surface Configurations. J. Fluids Eng. 1992, 114, 170–177. [Google Scholar] [CrossRef] [Scilit]
- Zhang, H.L.; Ko, N.W. Numerical analysis of incompressible flow over smooth and grooved circular cylinders. Comput. Fluids 1996, 25, 263–281. [Google Scholar] [CrossRef] [Scilit]
- Lim, H.C.; Lee, S.J. Flow control of circular cylinders with longitudinal grooved surfaces. AIAA J. 2002, 40, 2027–2036. [Google Scholar] [CrossRef] [Scilit]
- Yamagishi, Y.; Oki, M. Effect of groove shape on flow characteristics around a circular cylinder with grooves. J. Vis. 2004, 7, 209–216. [Google Scholar] [CrossRef] [Scilit]
- Babu, P.; Mahesh, K. Aerodynamic loads on cactus-shaped cylinders at low Reynolds numbers. Phys. Fluids 2008, 20, 035112. [Google Scholar] [CrossRef] [Scilit]
- Seo, S.H.; Nam, C.D.; Han, J.Y.; Hong, C.H. Drag reduction of a bluff body by grooves laid out by design of experiment. J. Fluids Eng. 2013, 135, 111202. [Google Scholar] [CrossRef] [Scilit]
- Canpolat, C. Characteristics of flow past a circular cylinder with a rectangular groove. Flow Meas. Instrum. 2015, 45, 233–246. [Google Scholar] [CrossRef] [Scilit]
- Zhou, B.; Wang, X.; Guo, W.; Zheng, J.; Tan, S.K. Experimental measurements of the drag force and the near-wake flow patterns of a longitudinally grooved cylinder. J. Wind. Eng. Ind. Aerodyn. 2015, 145, 30–41. [Google Scholar] [CrossRef] [Scilit]
- Abdi, M.; Menouer, A.; Chaib, K.; Benferhat, S.; Chemloul, N.S.; Kadari, A. Momentum and heat transfer characteristics for Newtonian fluid across a grooved cylinder. Int. J. Mod. Phys. C 2022, 33, 2250109. [Google Scholar] [CrossRef] [Scilit]
- Afroz, F.; Sharif, M.A. Numerical study of cross-flow around a circular cylinder with differently shaped span-wise surface grooves at low Reynolds number. Eur. J. Mech.-B/Fluids 2022, 91, 203–218. [Google Scholar] [CrossRef] [Scilit]
- Verma, G.; Bharti, C.K.; Barman, R.N. Impact of groove on flow patterns and heat transfer over circular cylinders: A power-law fluid perspective. Phys. Fluids 2025, 37, 043121. [Google Scholar] [CrossRef] [Scilit]
- Pan, F.; Acrivos, A. Steady flows in rectangular cavities. J. Fluid Mech. 1967, 28, 643–655. [Google Scholar] [CrossRef] [Scilit]
- Matsson, J.E. An Introduction to ANSYS Fluent 2022; SDC Publications: Mission, KS, USA, 2022. [Google Scholar]
- Fornberg, B. A numerical study of steady viscous flow past a circular cylinder. J. Fluid Mech. 1980, 98, 819–855. [Google Scholar] [CrossRef] [Scilit]
- Coutanceau, M.; Bouard, R. Experimental determination of the main features of the viscous flow in the wake of a circular cylinder in uniform translation. Part 1. Steady flow. J. Fluid Mech. 1977, 79, 231–256. [Google Scholar] [CrossRef] [Scilit]
- Rajani, B.N.; Kandasamy, A.; Majumdar, S. Numerical simulation of laminar flow past a circular cylinder. Appl. Math. Model. 2009, 33, 1228–1247. [Google Scholar] [CrossRef] [Scilit]
- Henderson, R.D. Details of the drag curve near the onset of vortex shedding. Phys. Fluids 1995, 7, 2102–2104. [Google Scholar] [CrossRef] [Scilit]
- Takami, H.; Keller, H.B. Steady two-dimensional viscous flow of an incompressible fluid past a circular cylinder. Phys. Fluids 1969, 12, II-51. [Google Scholar] [CrossRef] [Scilit]
- Hamielec, A.E.; Raal, J.D. Numerical studies of viscous flow around circular cylinders. Phys. Fluids 1969, 12, 11–17. [Google Scholar] [CrossRef] [Scilit]
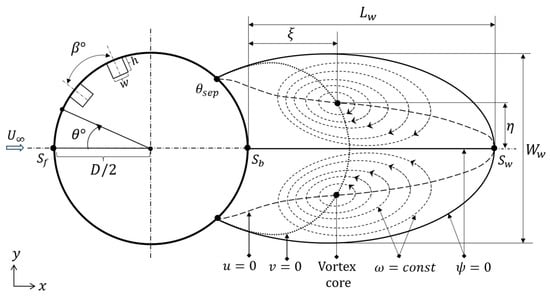
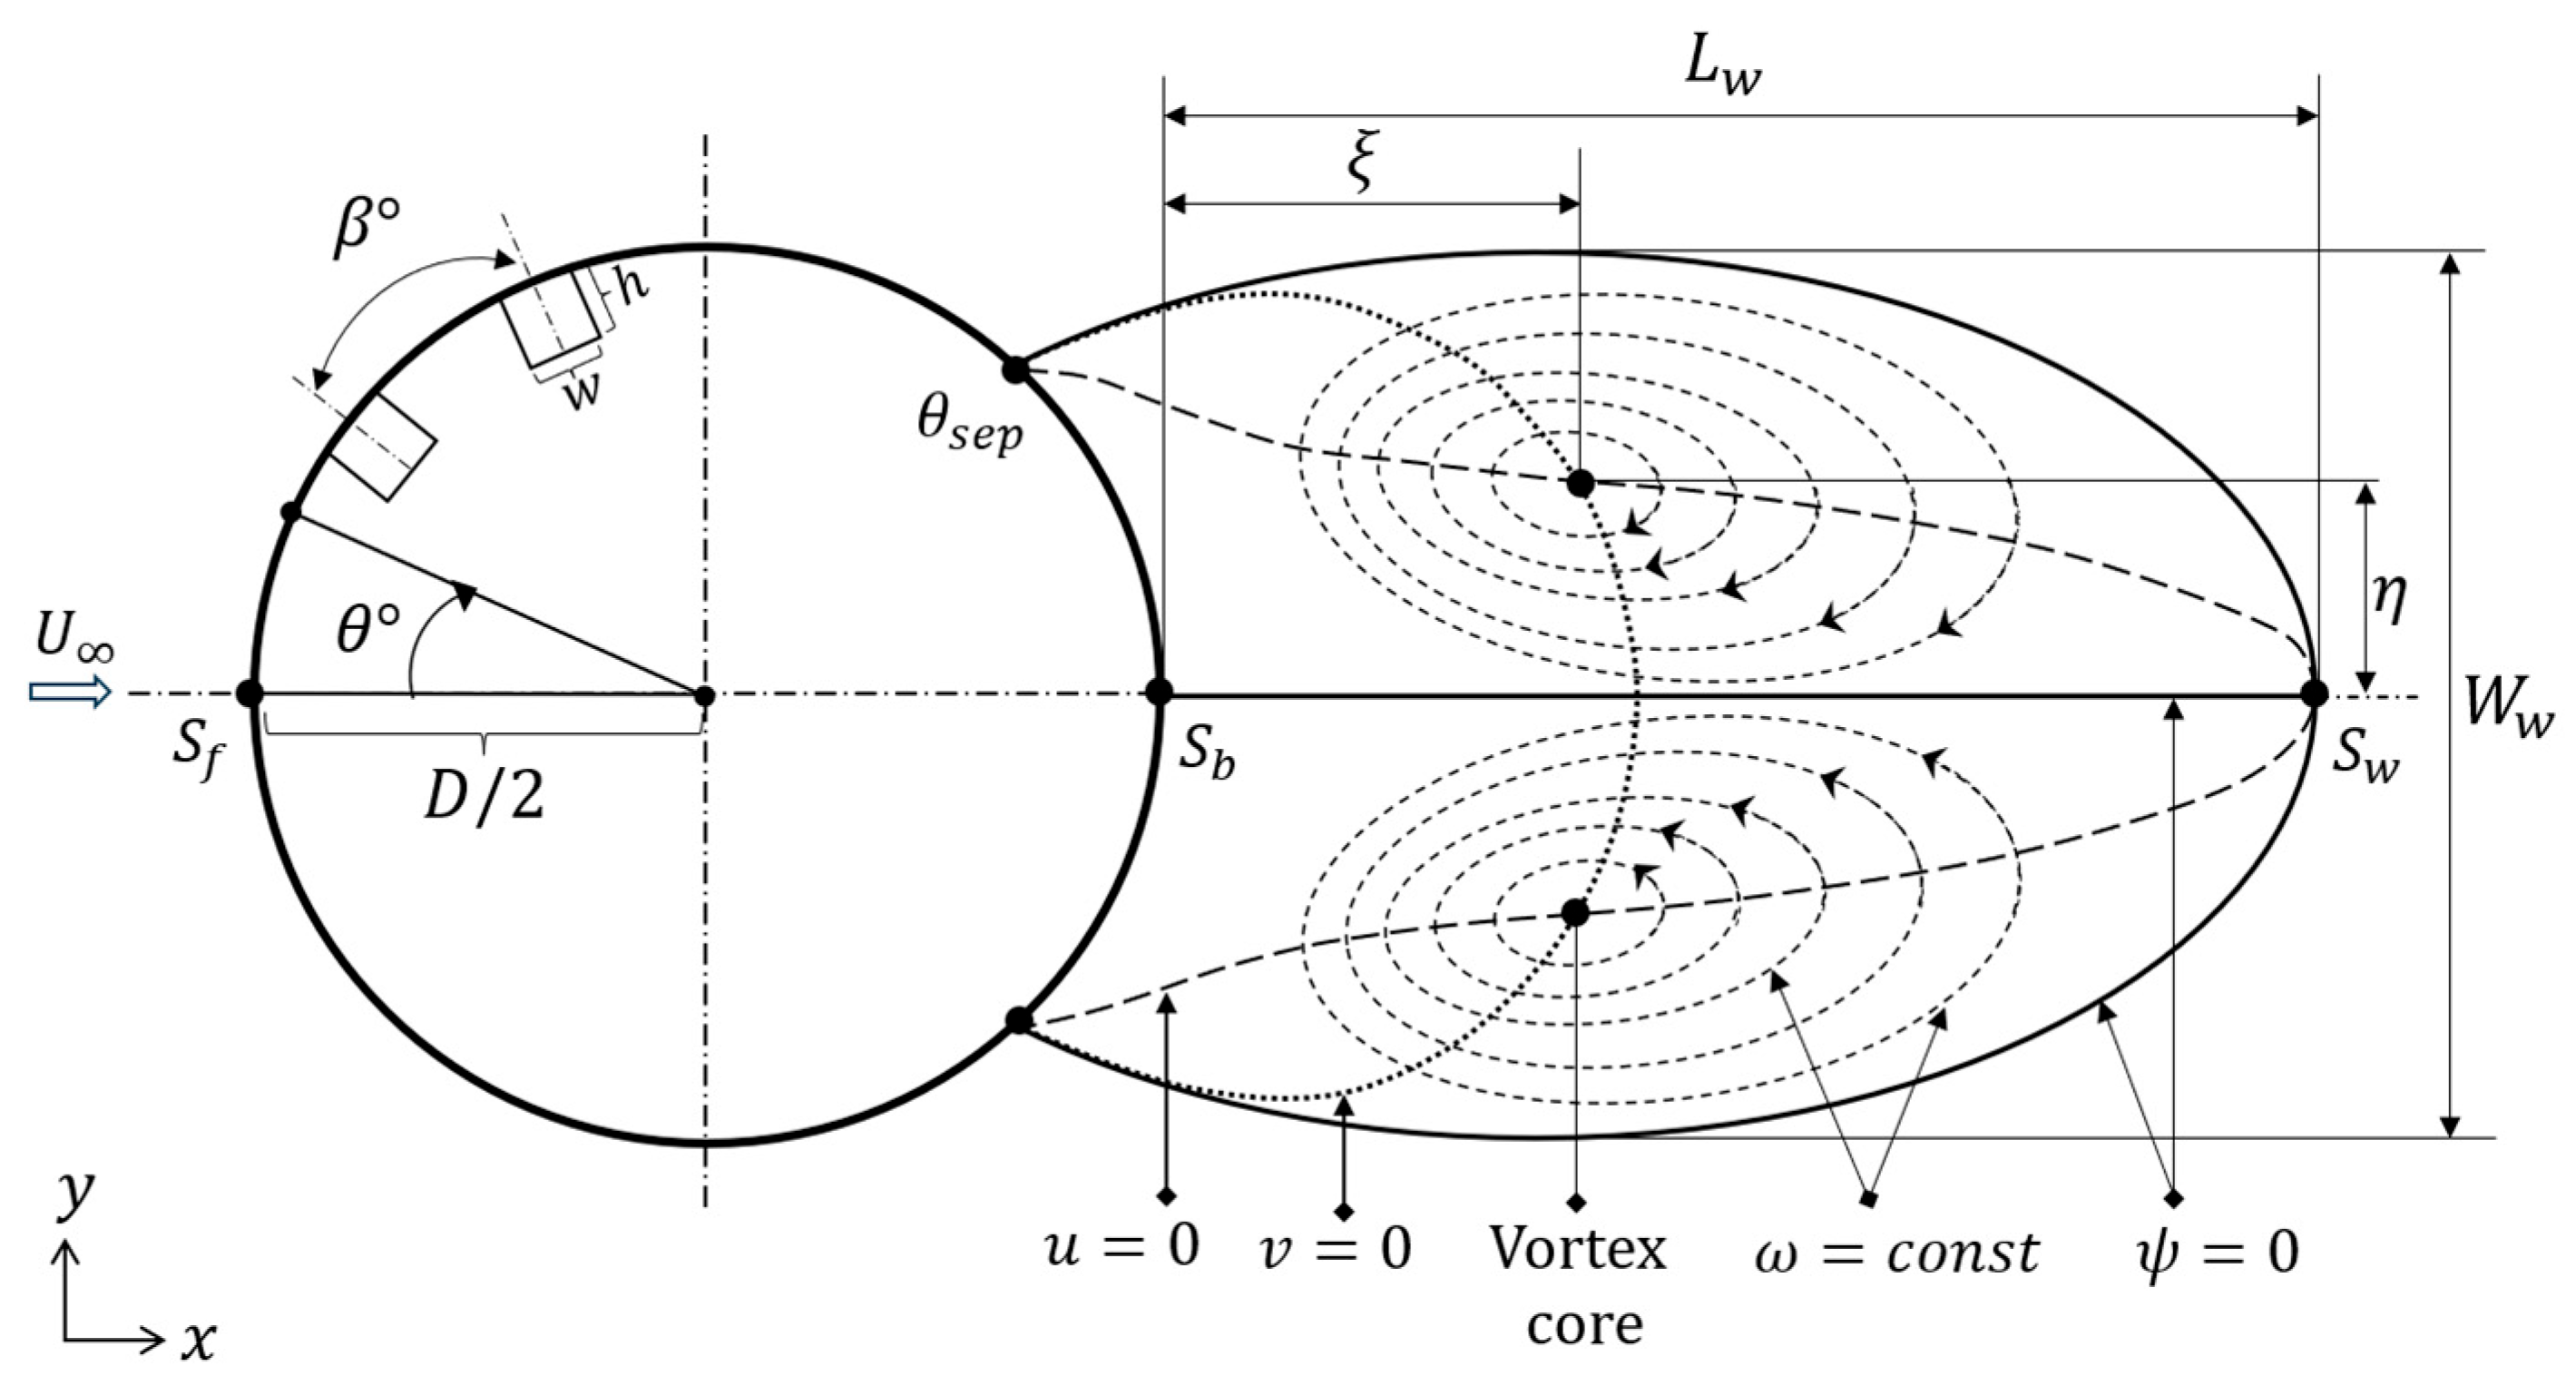
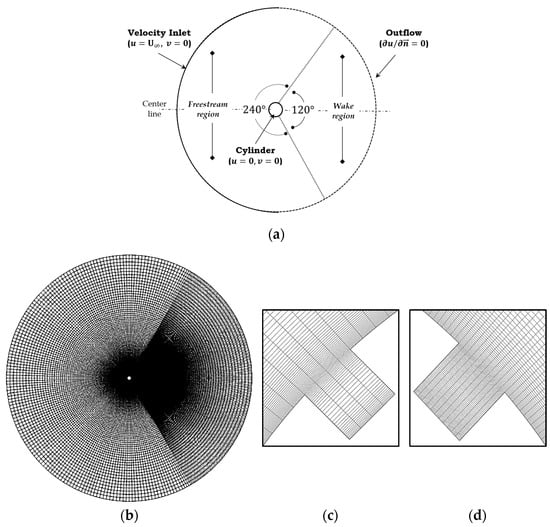
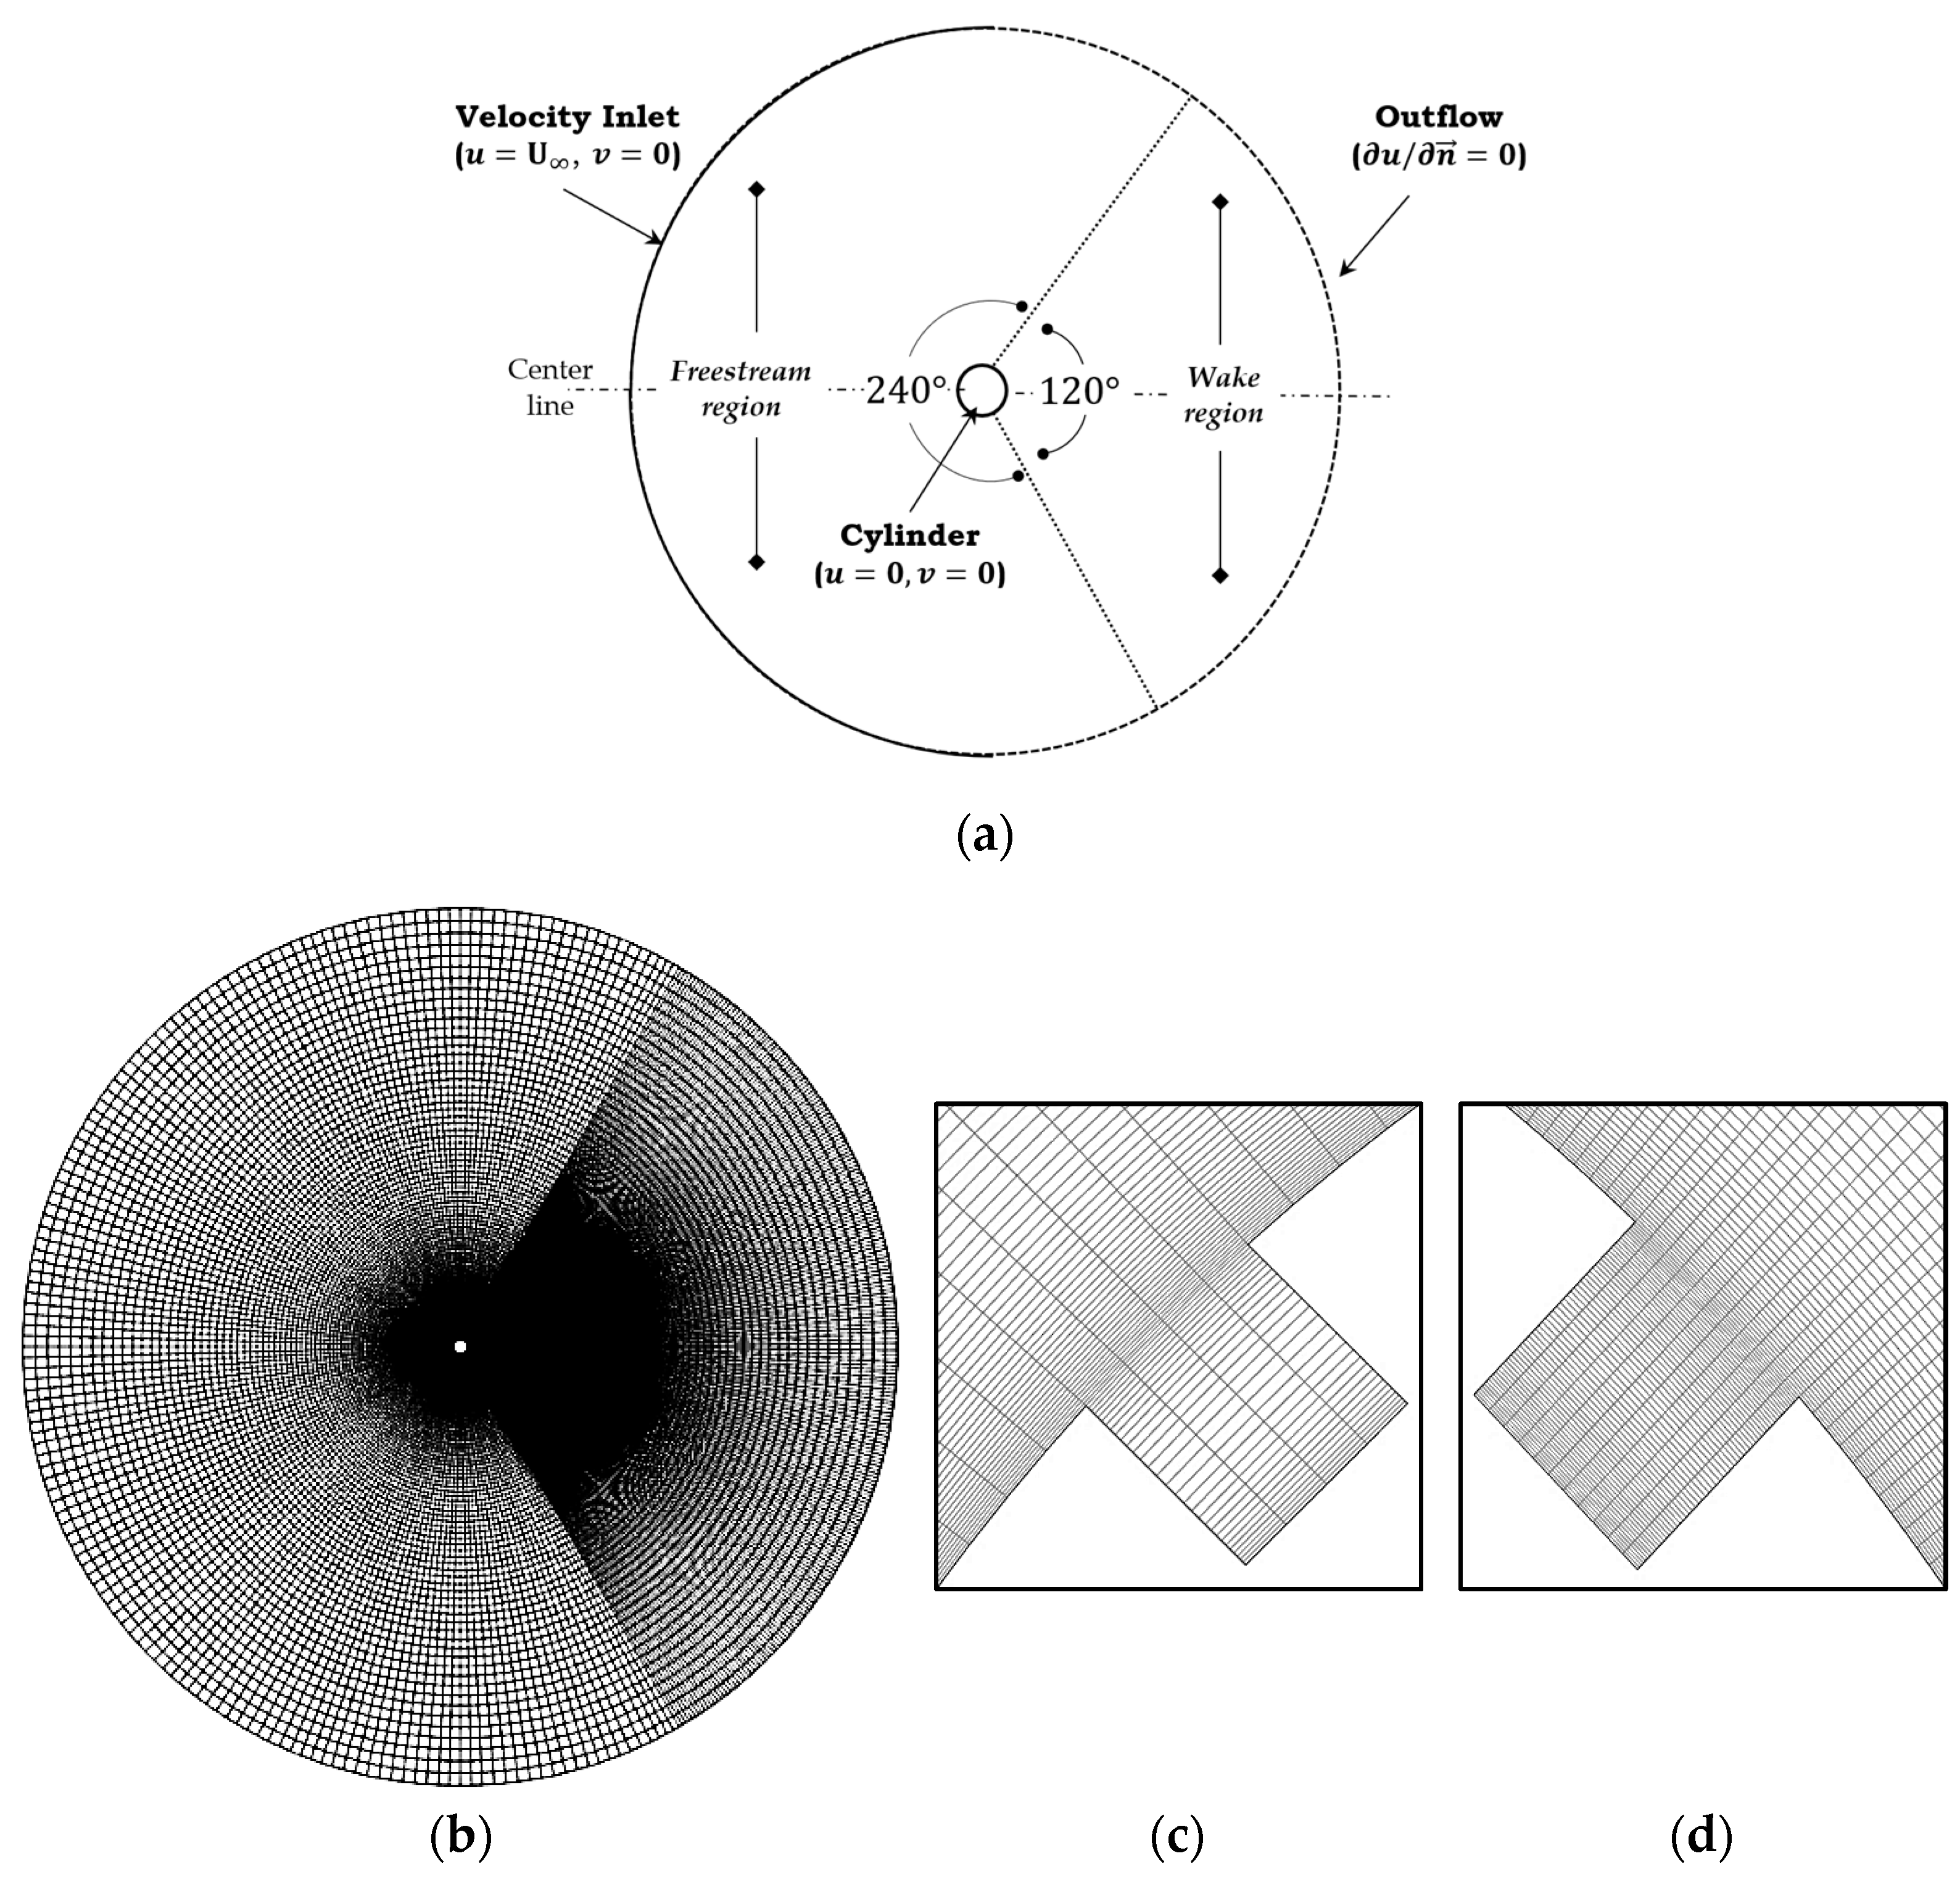
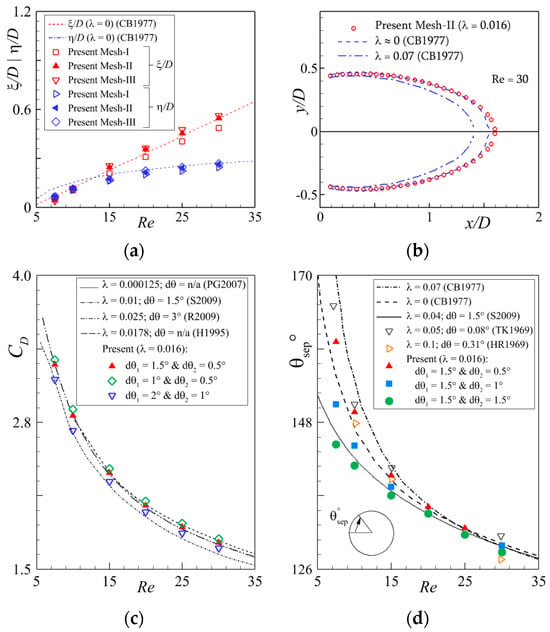
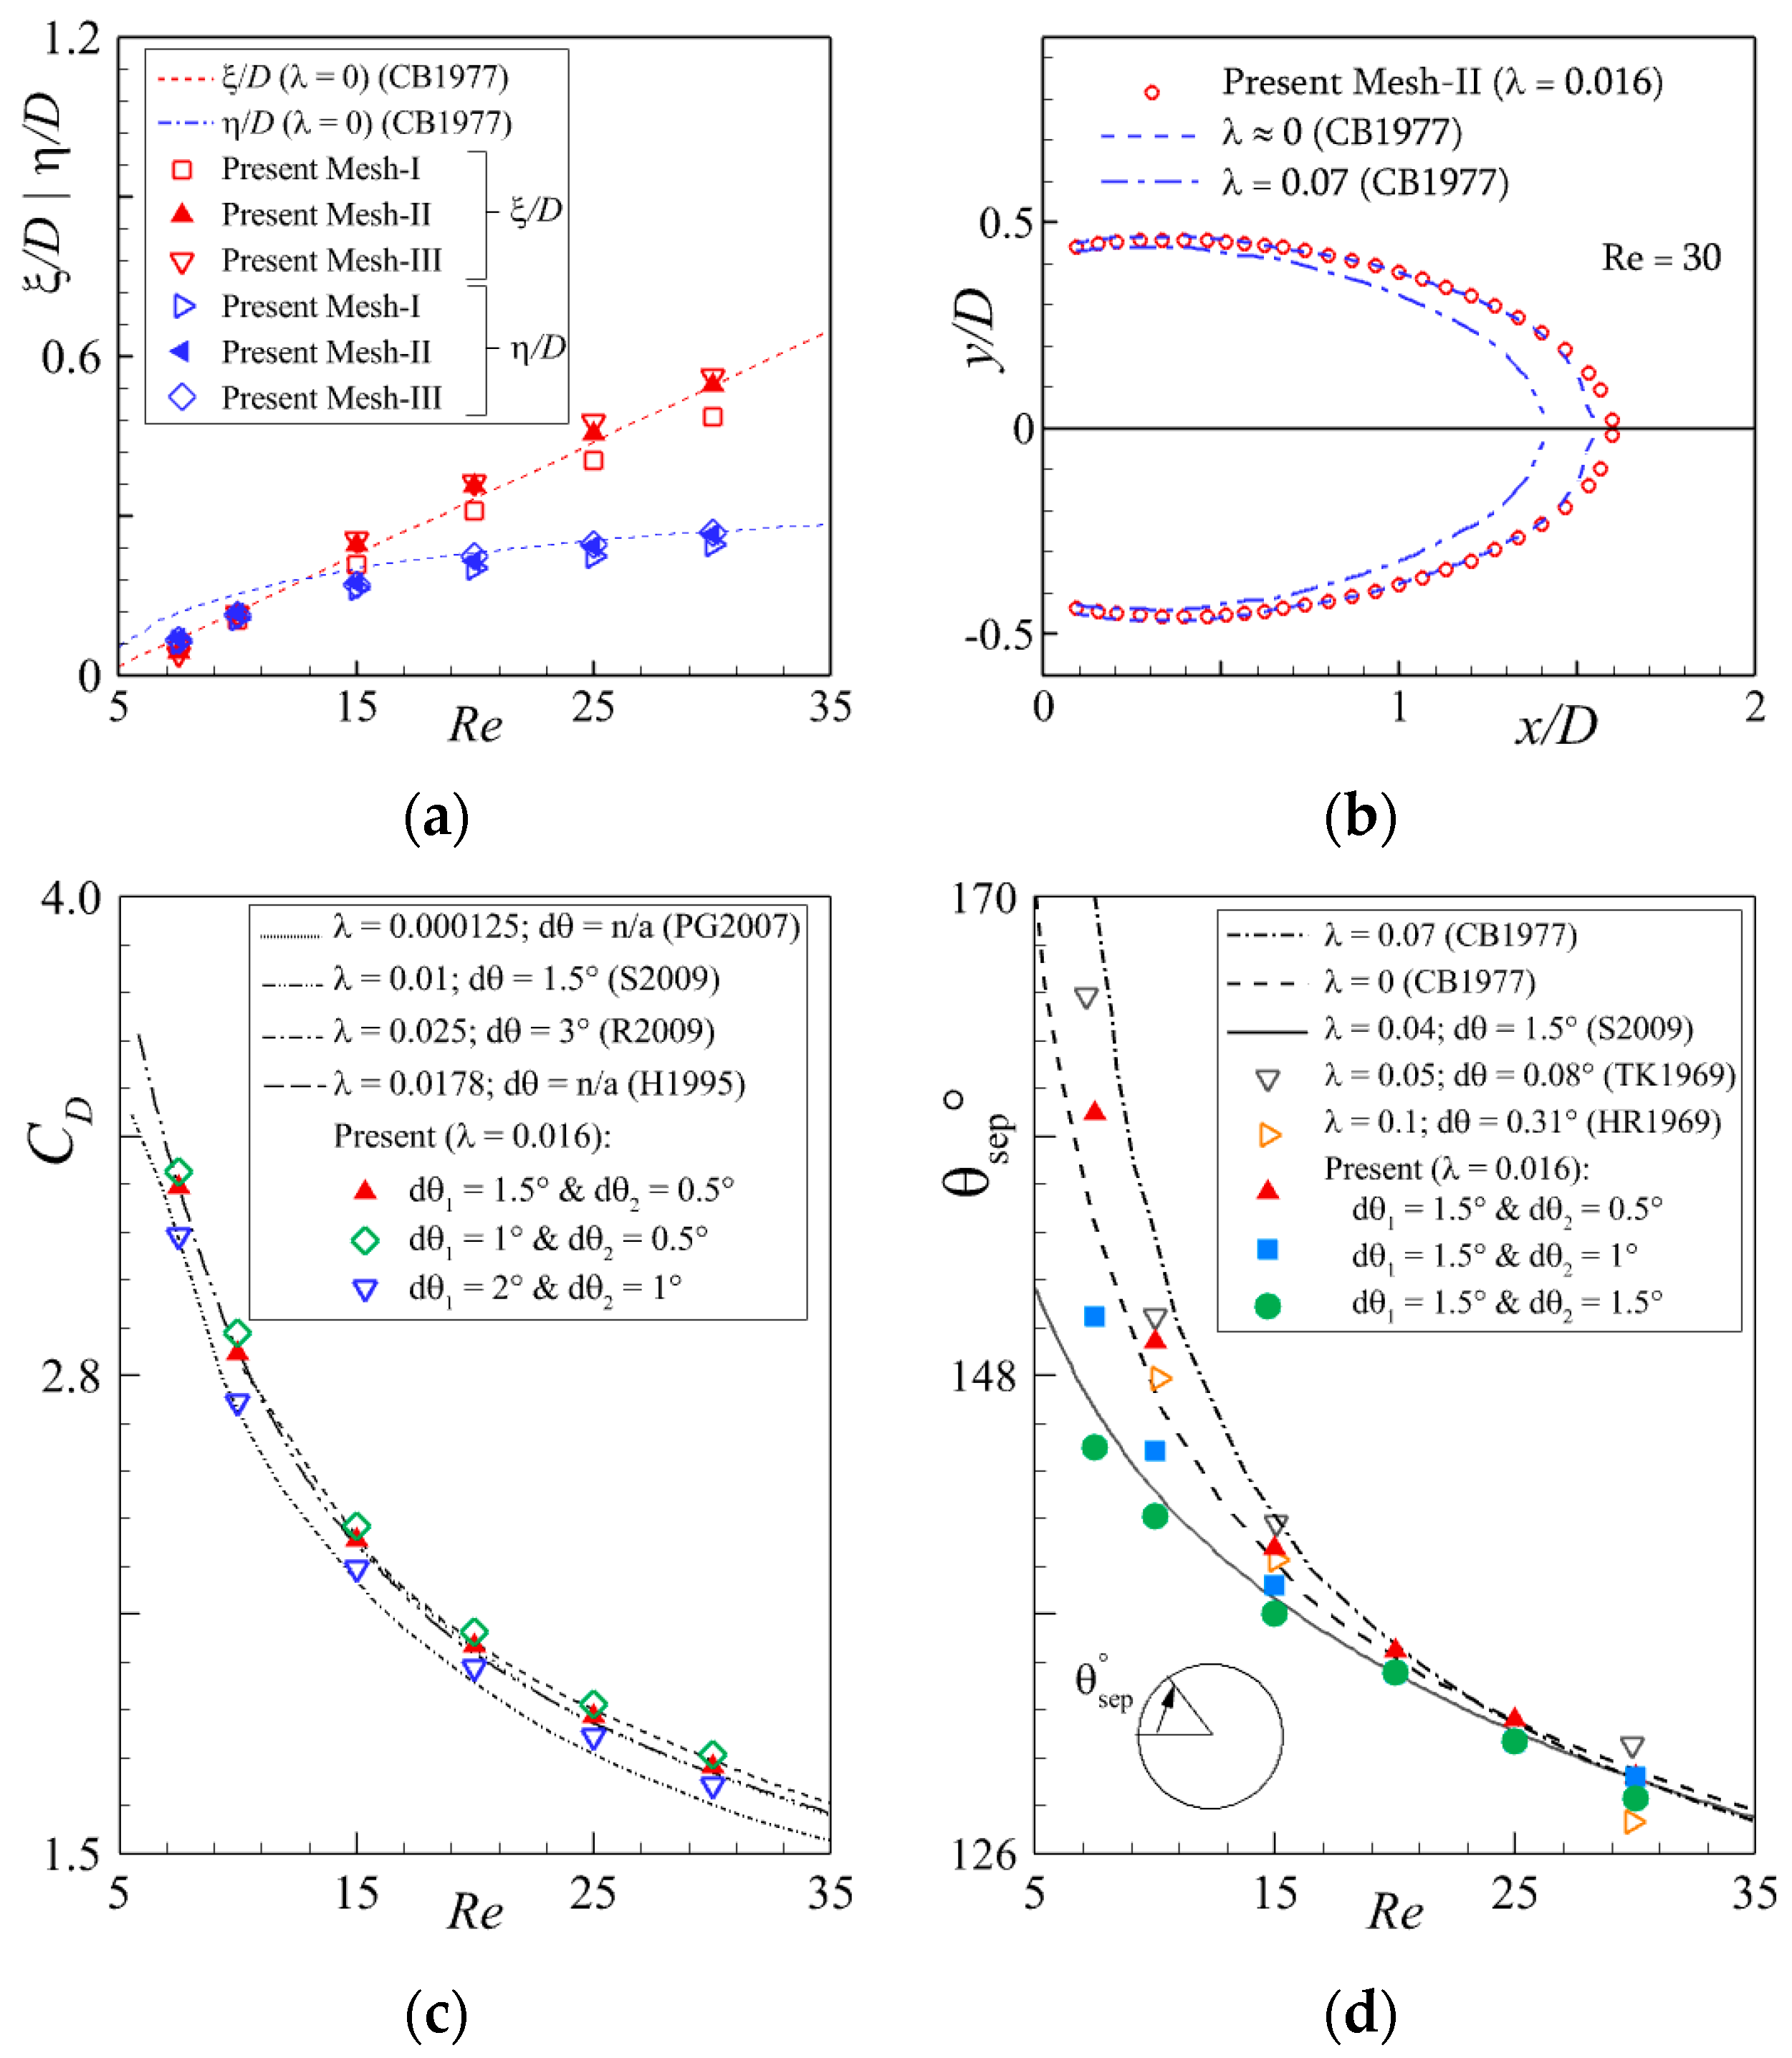
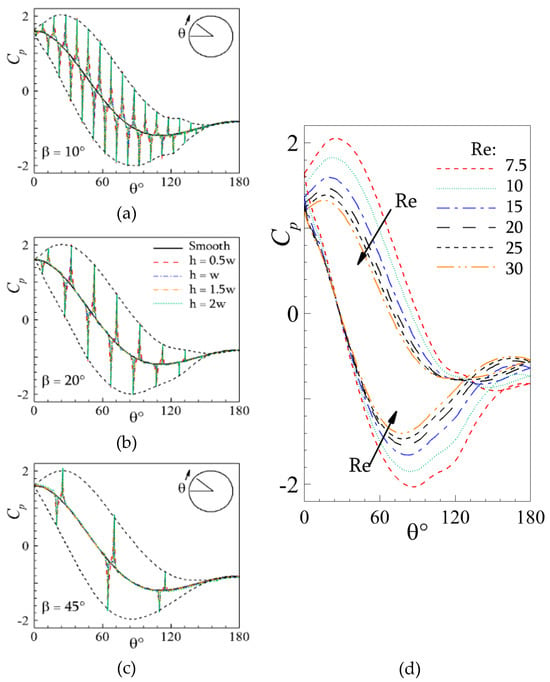
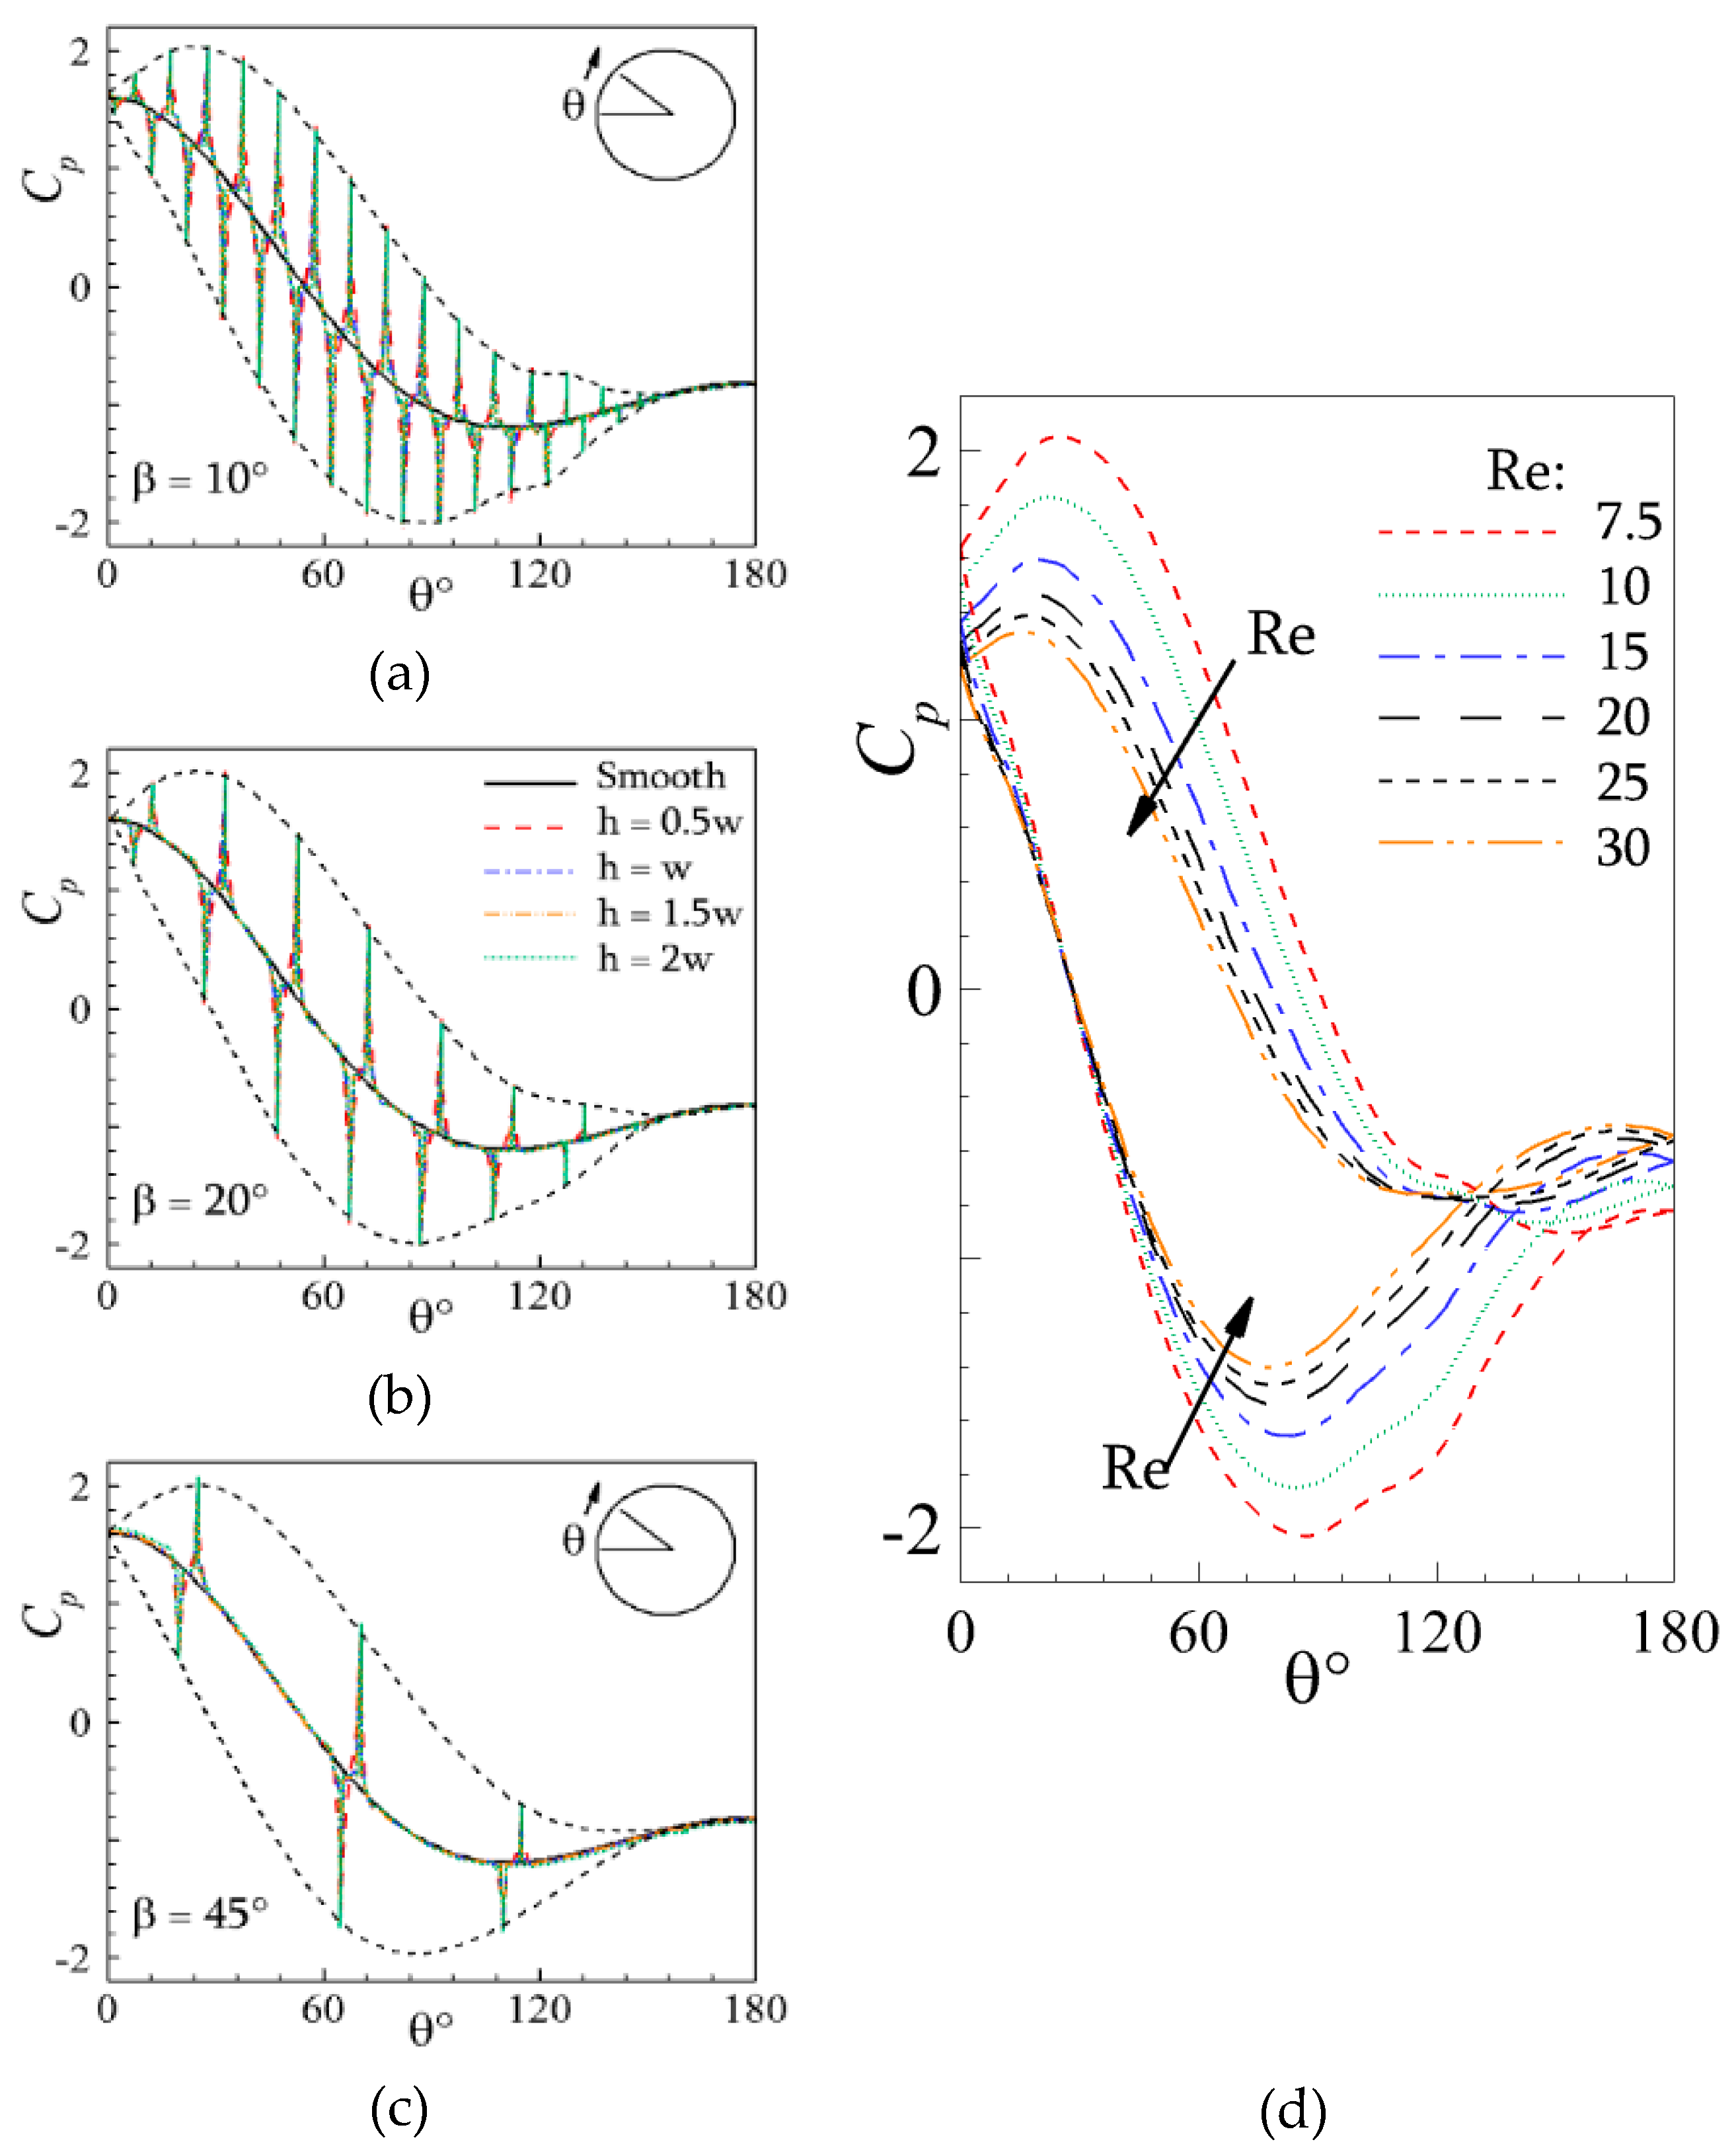
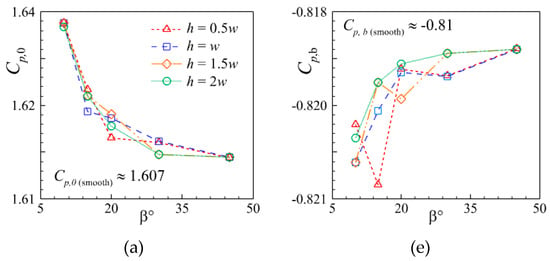
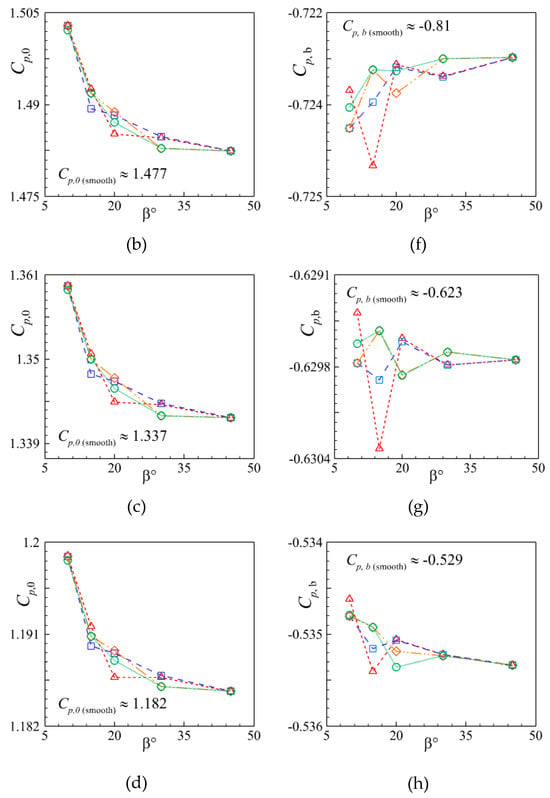
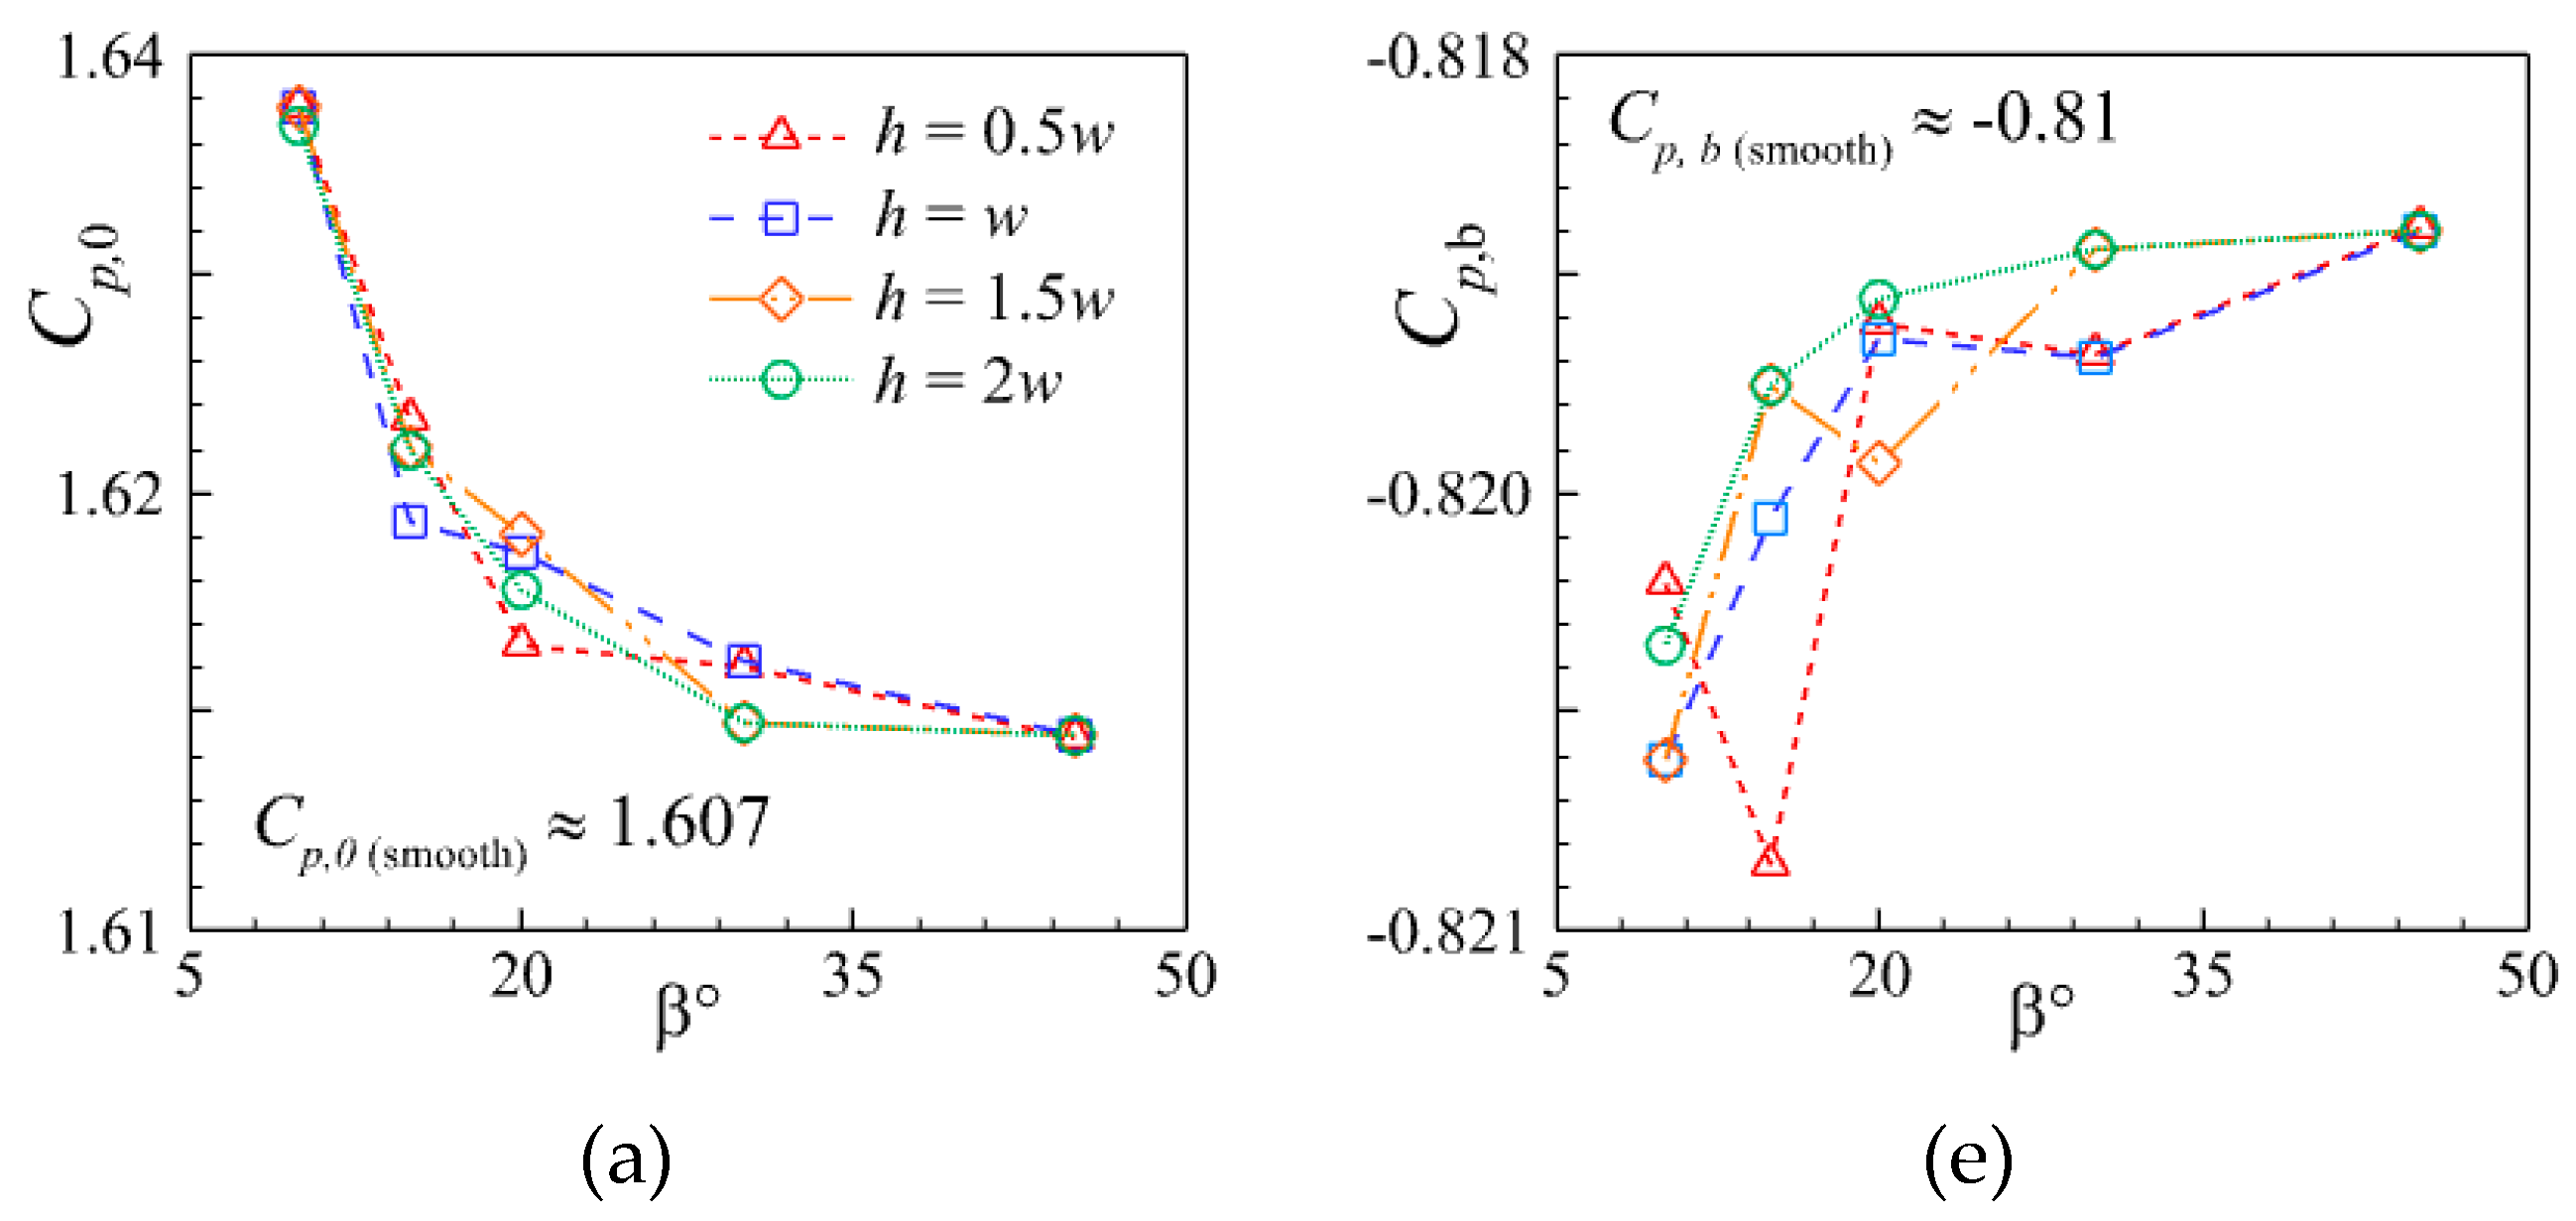
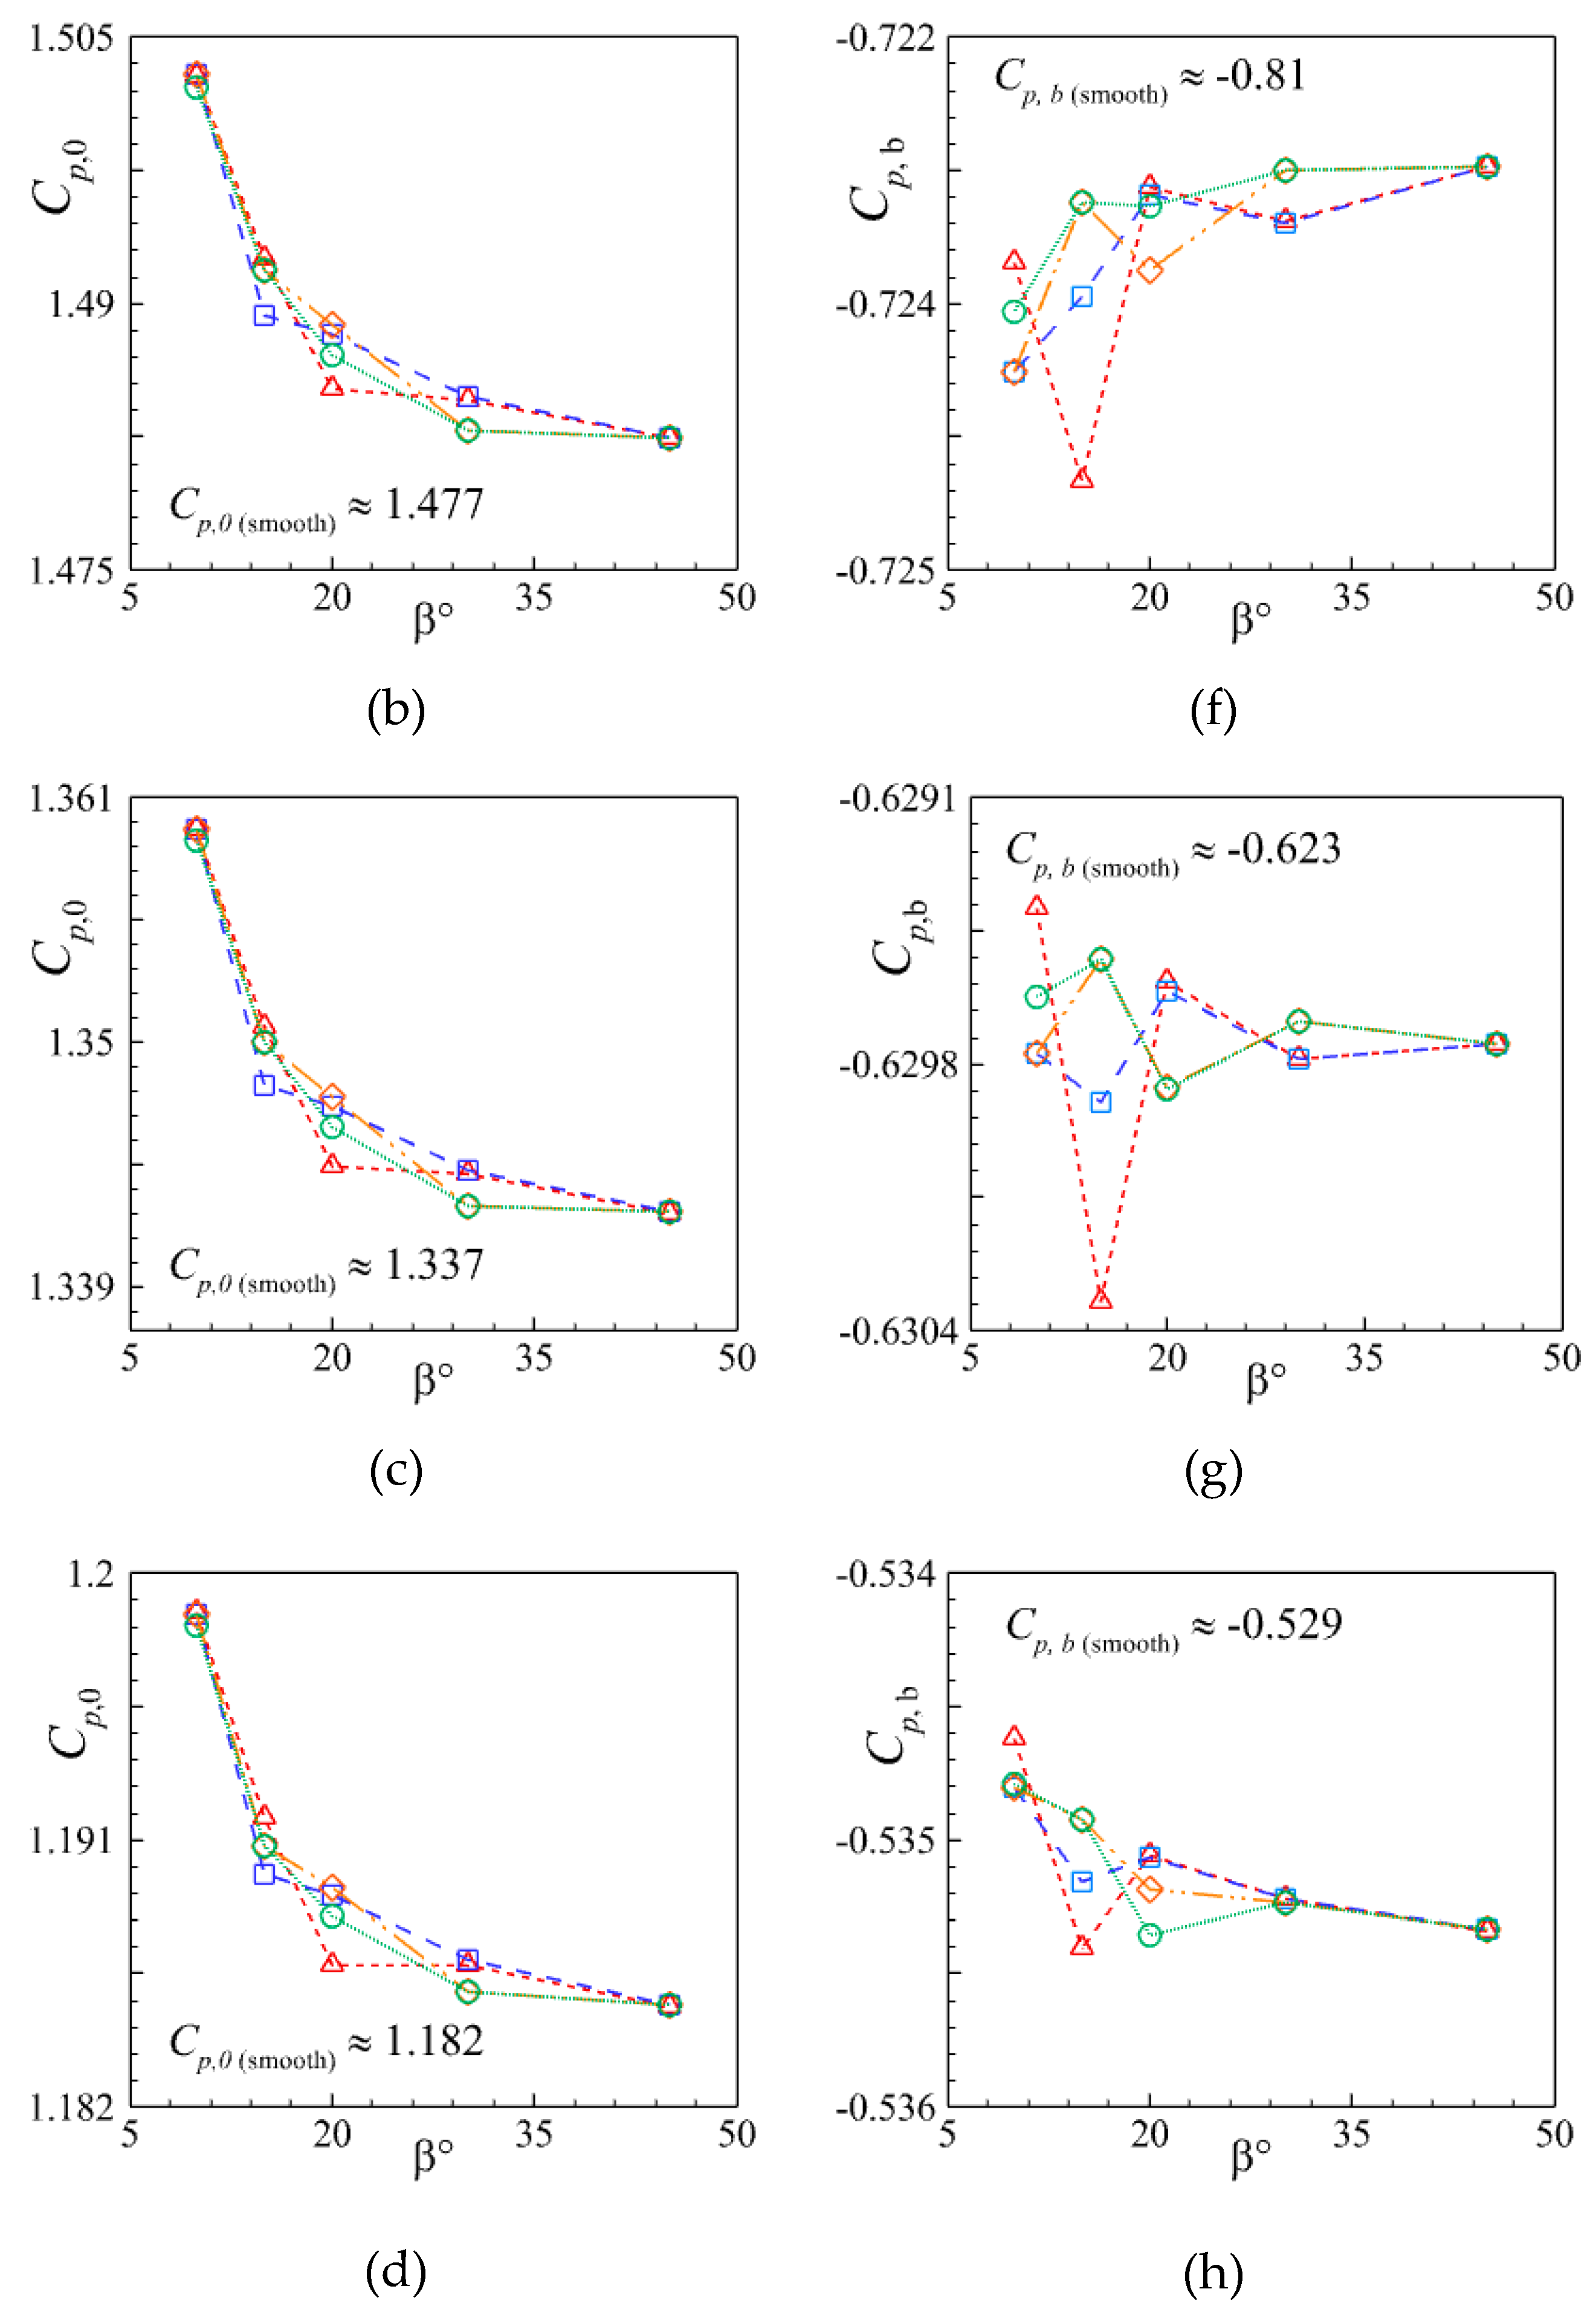
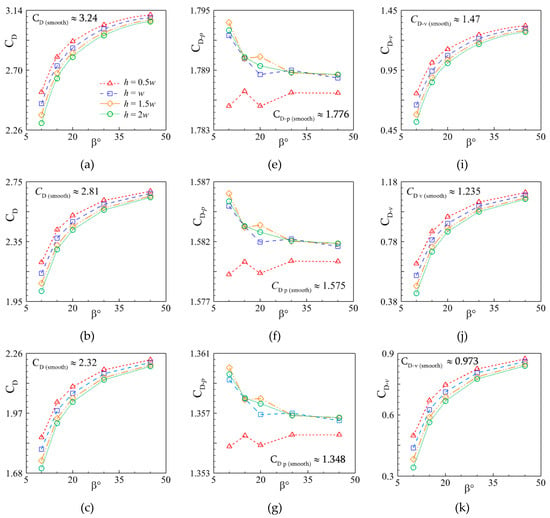
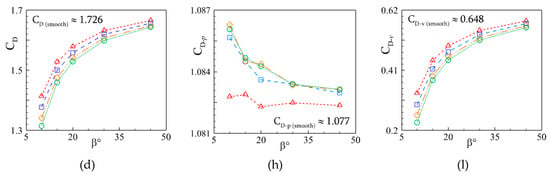
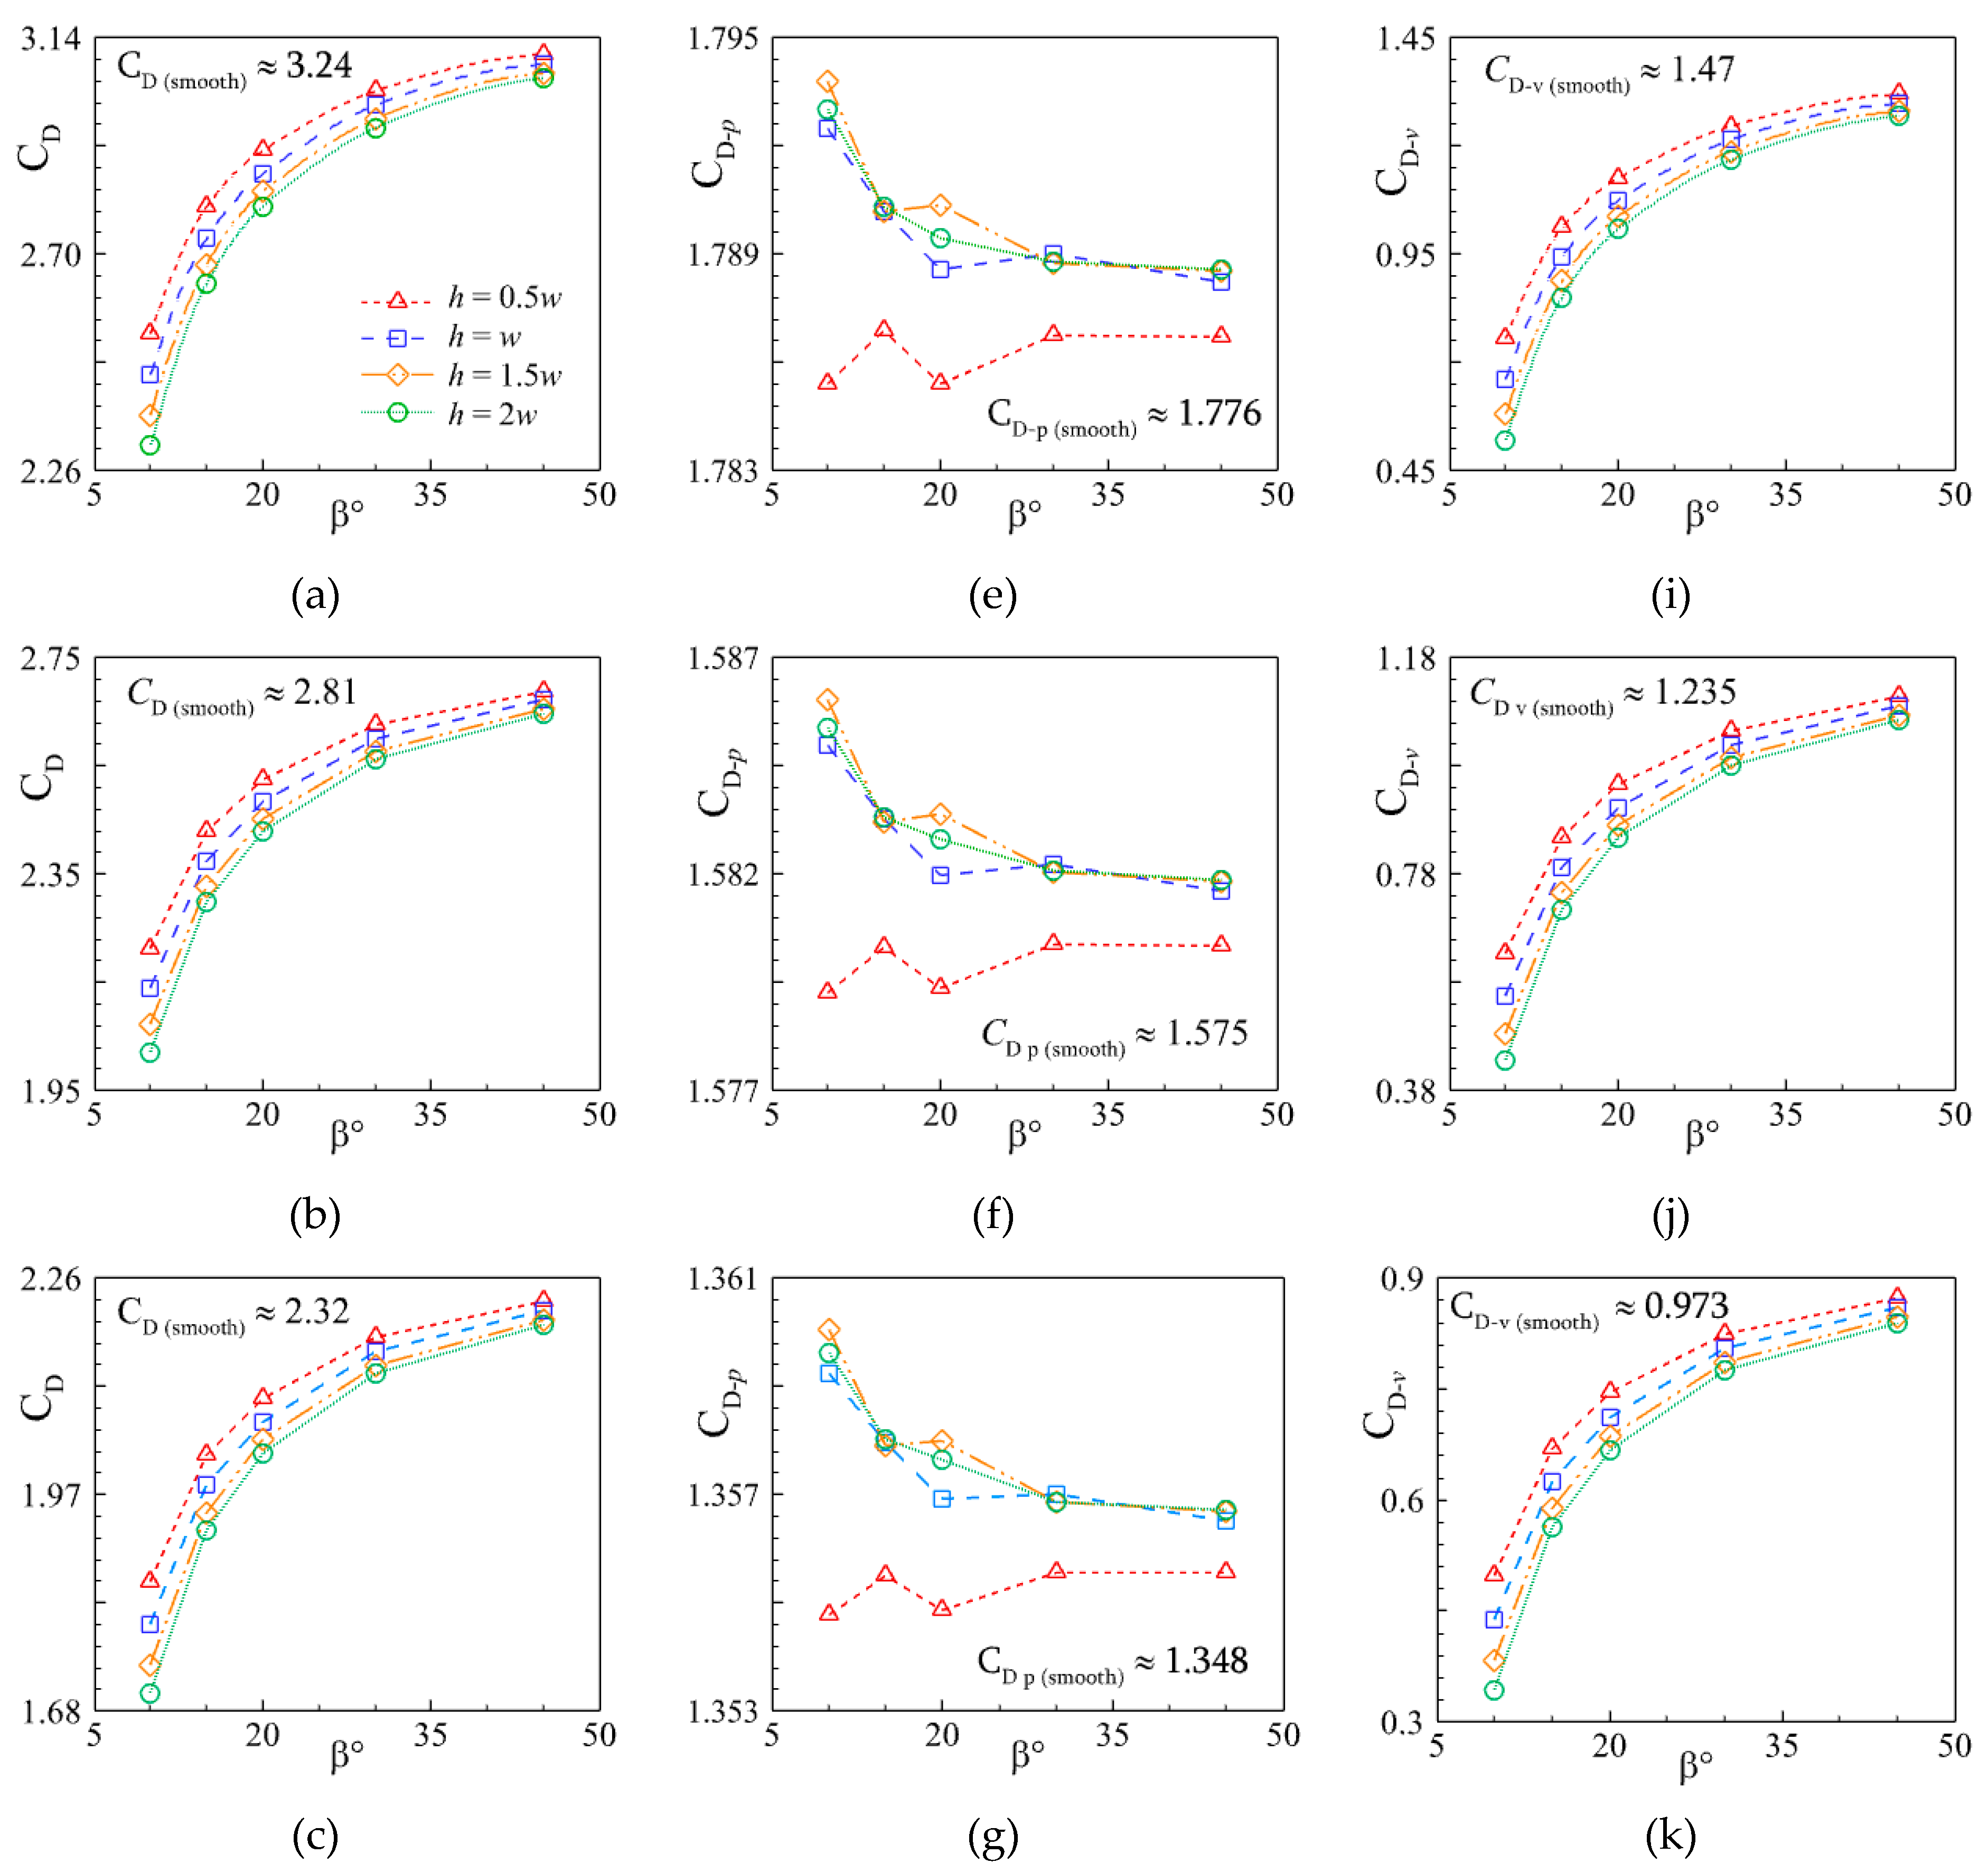
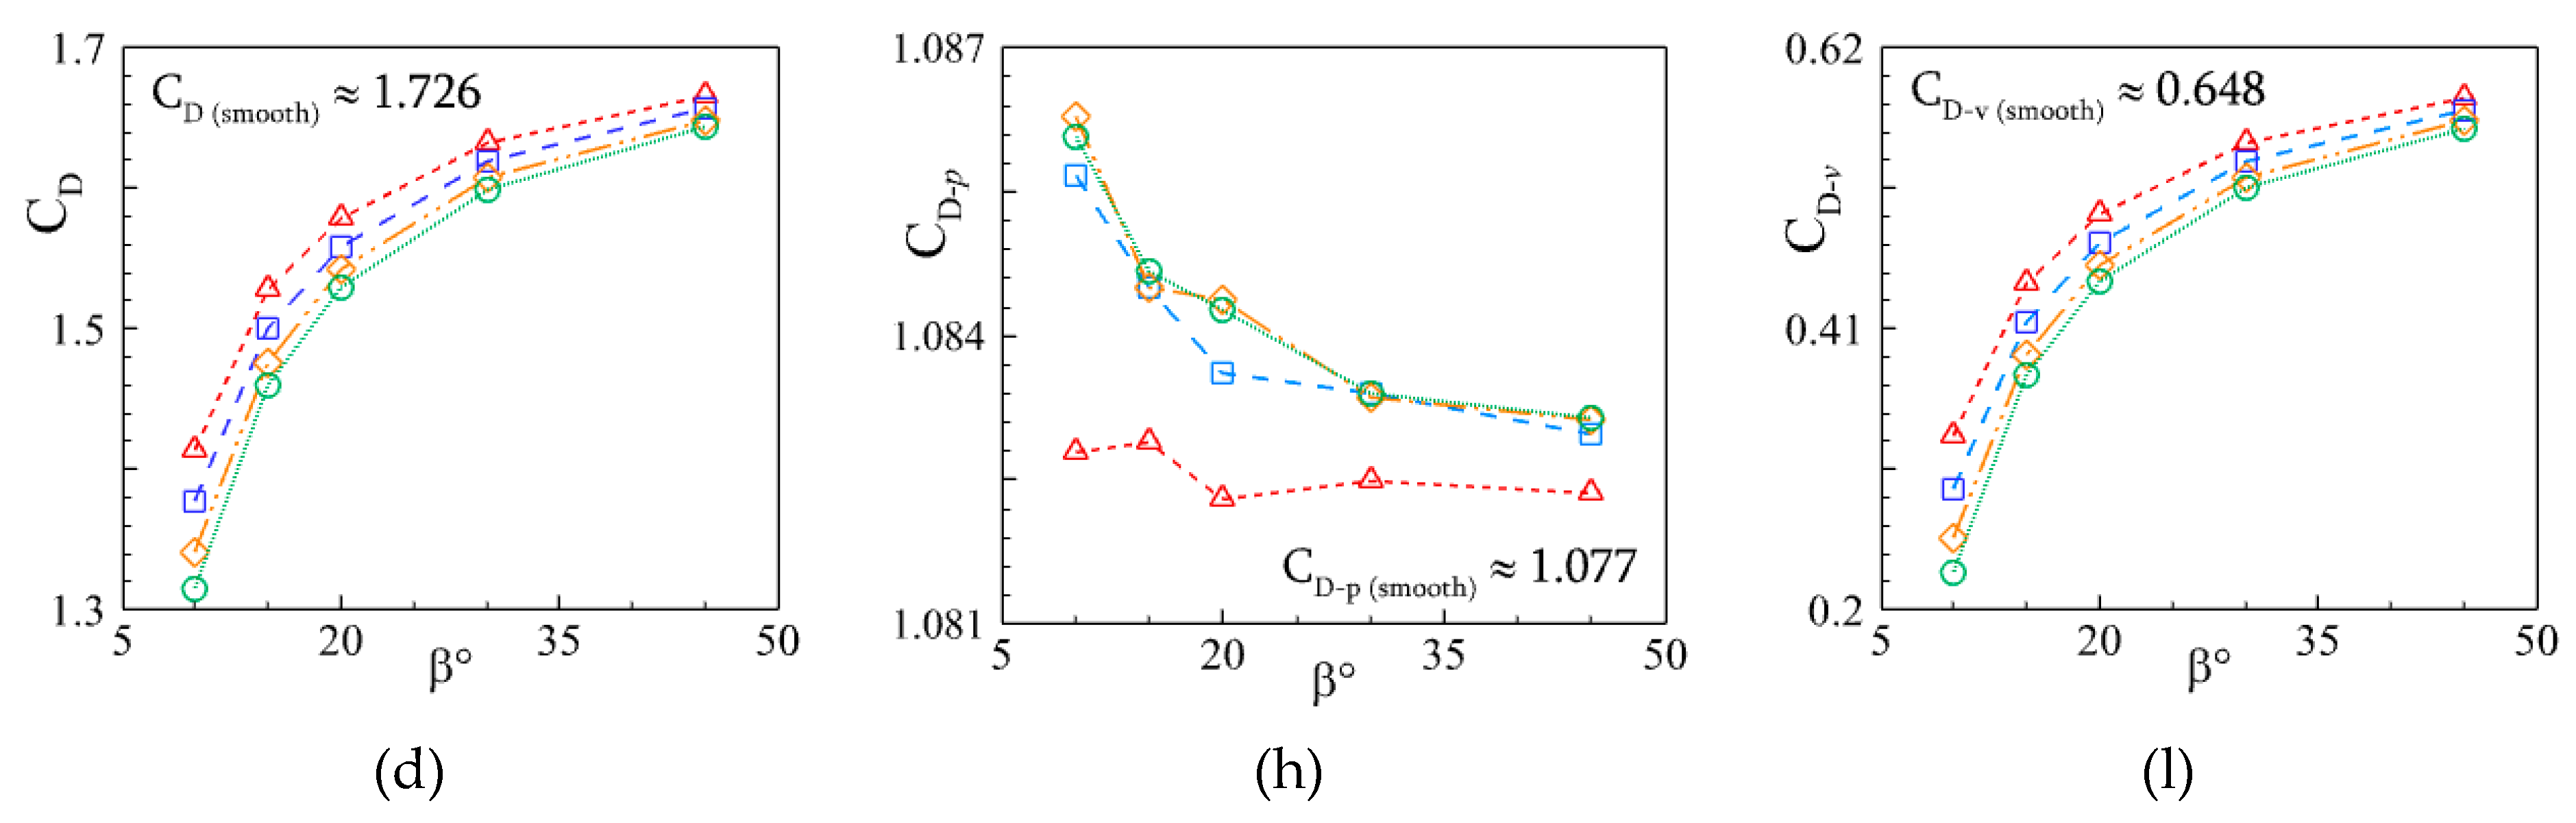
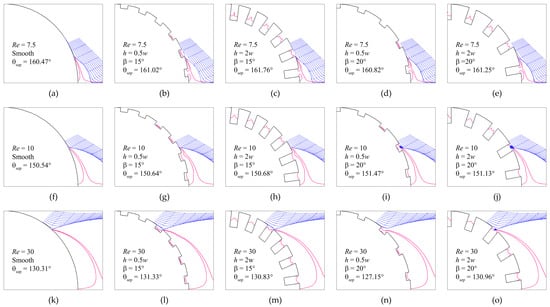
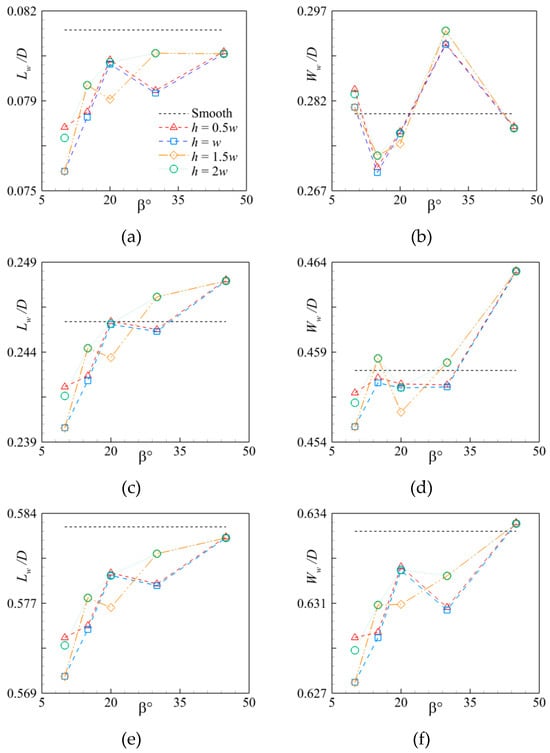
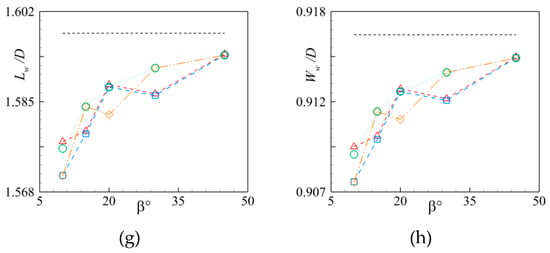
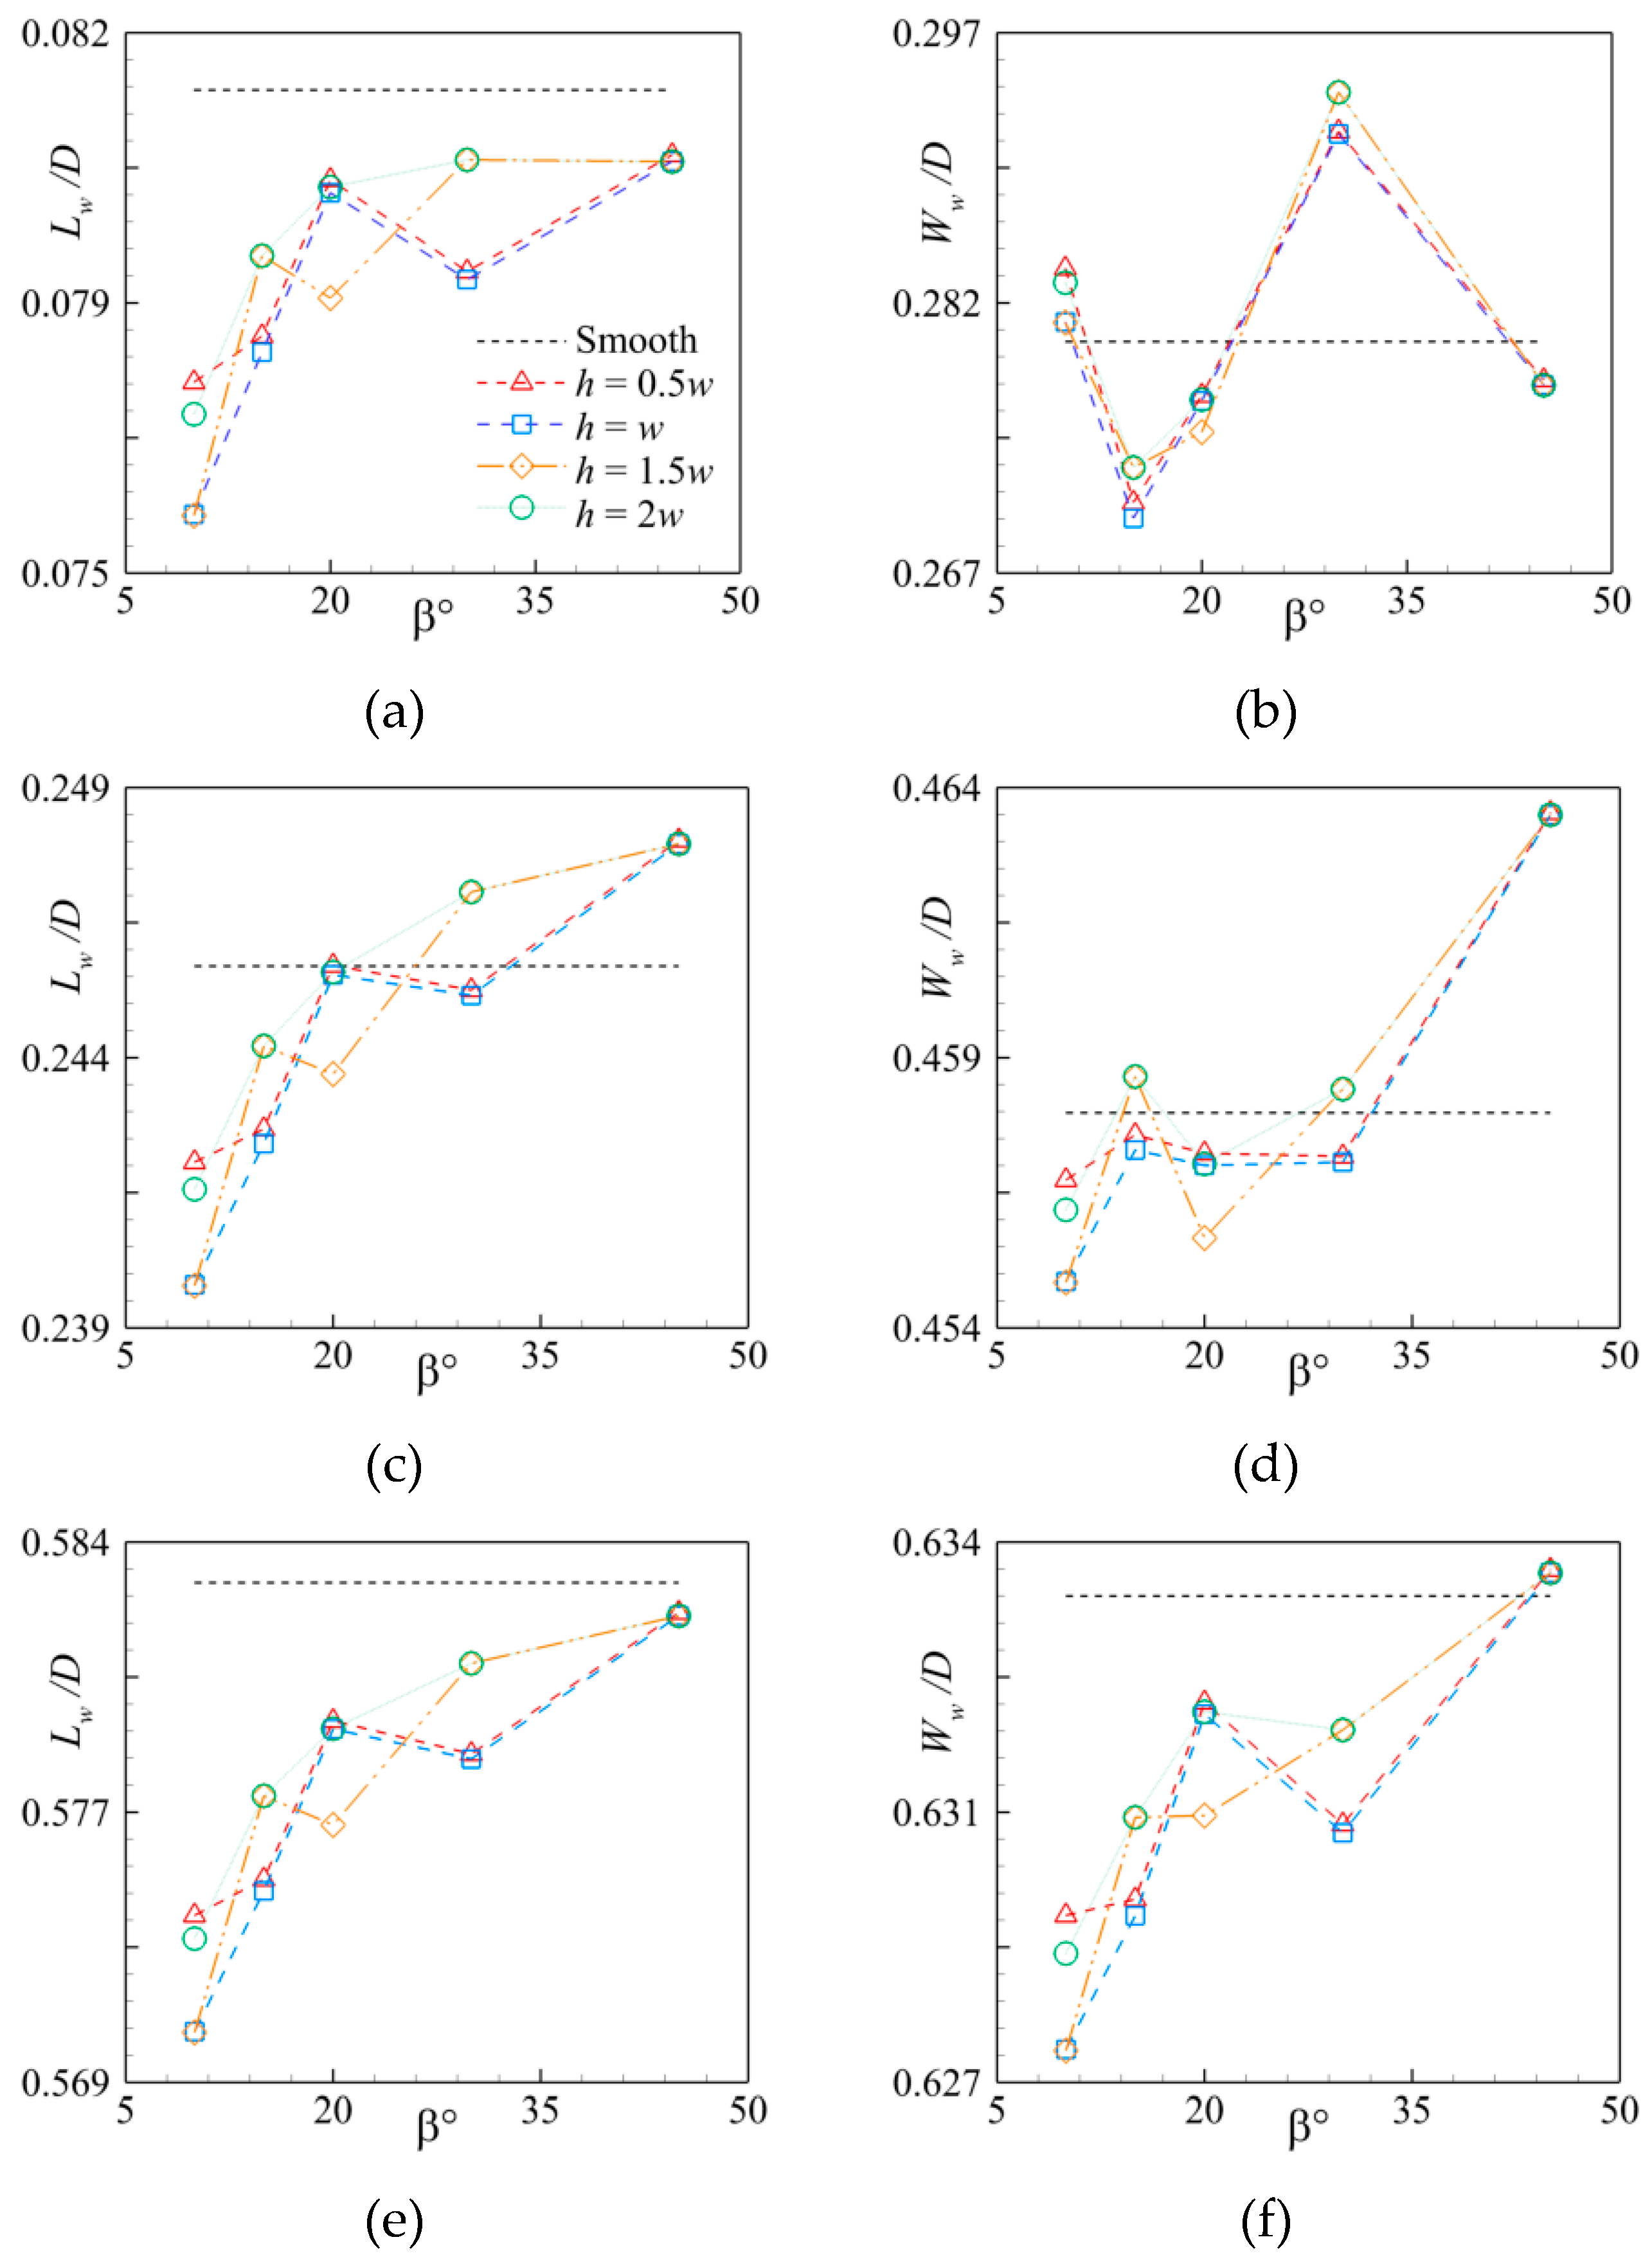
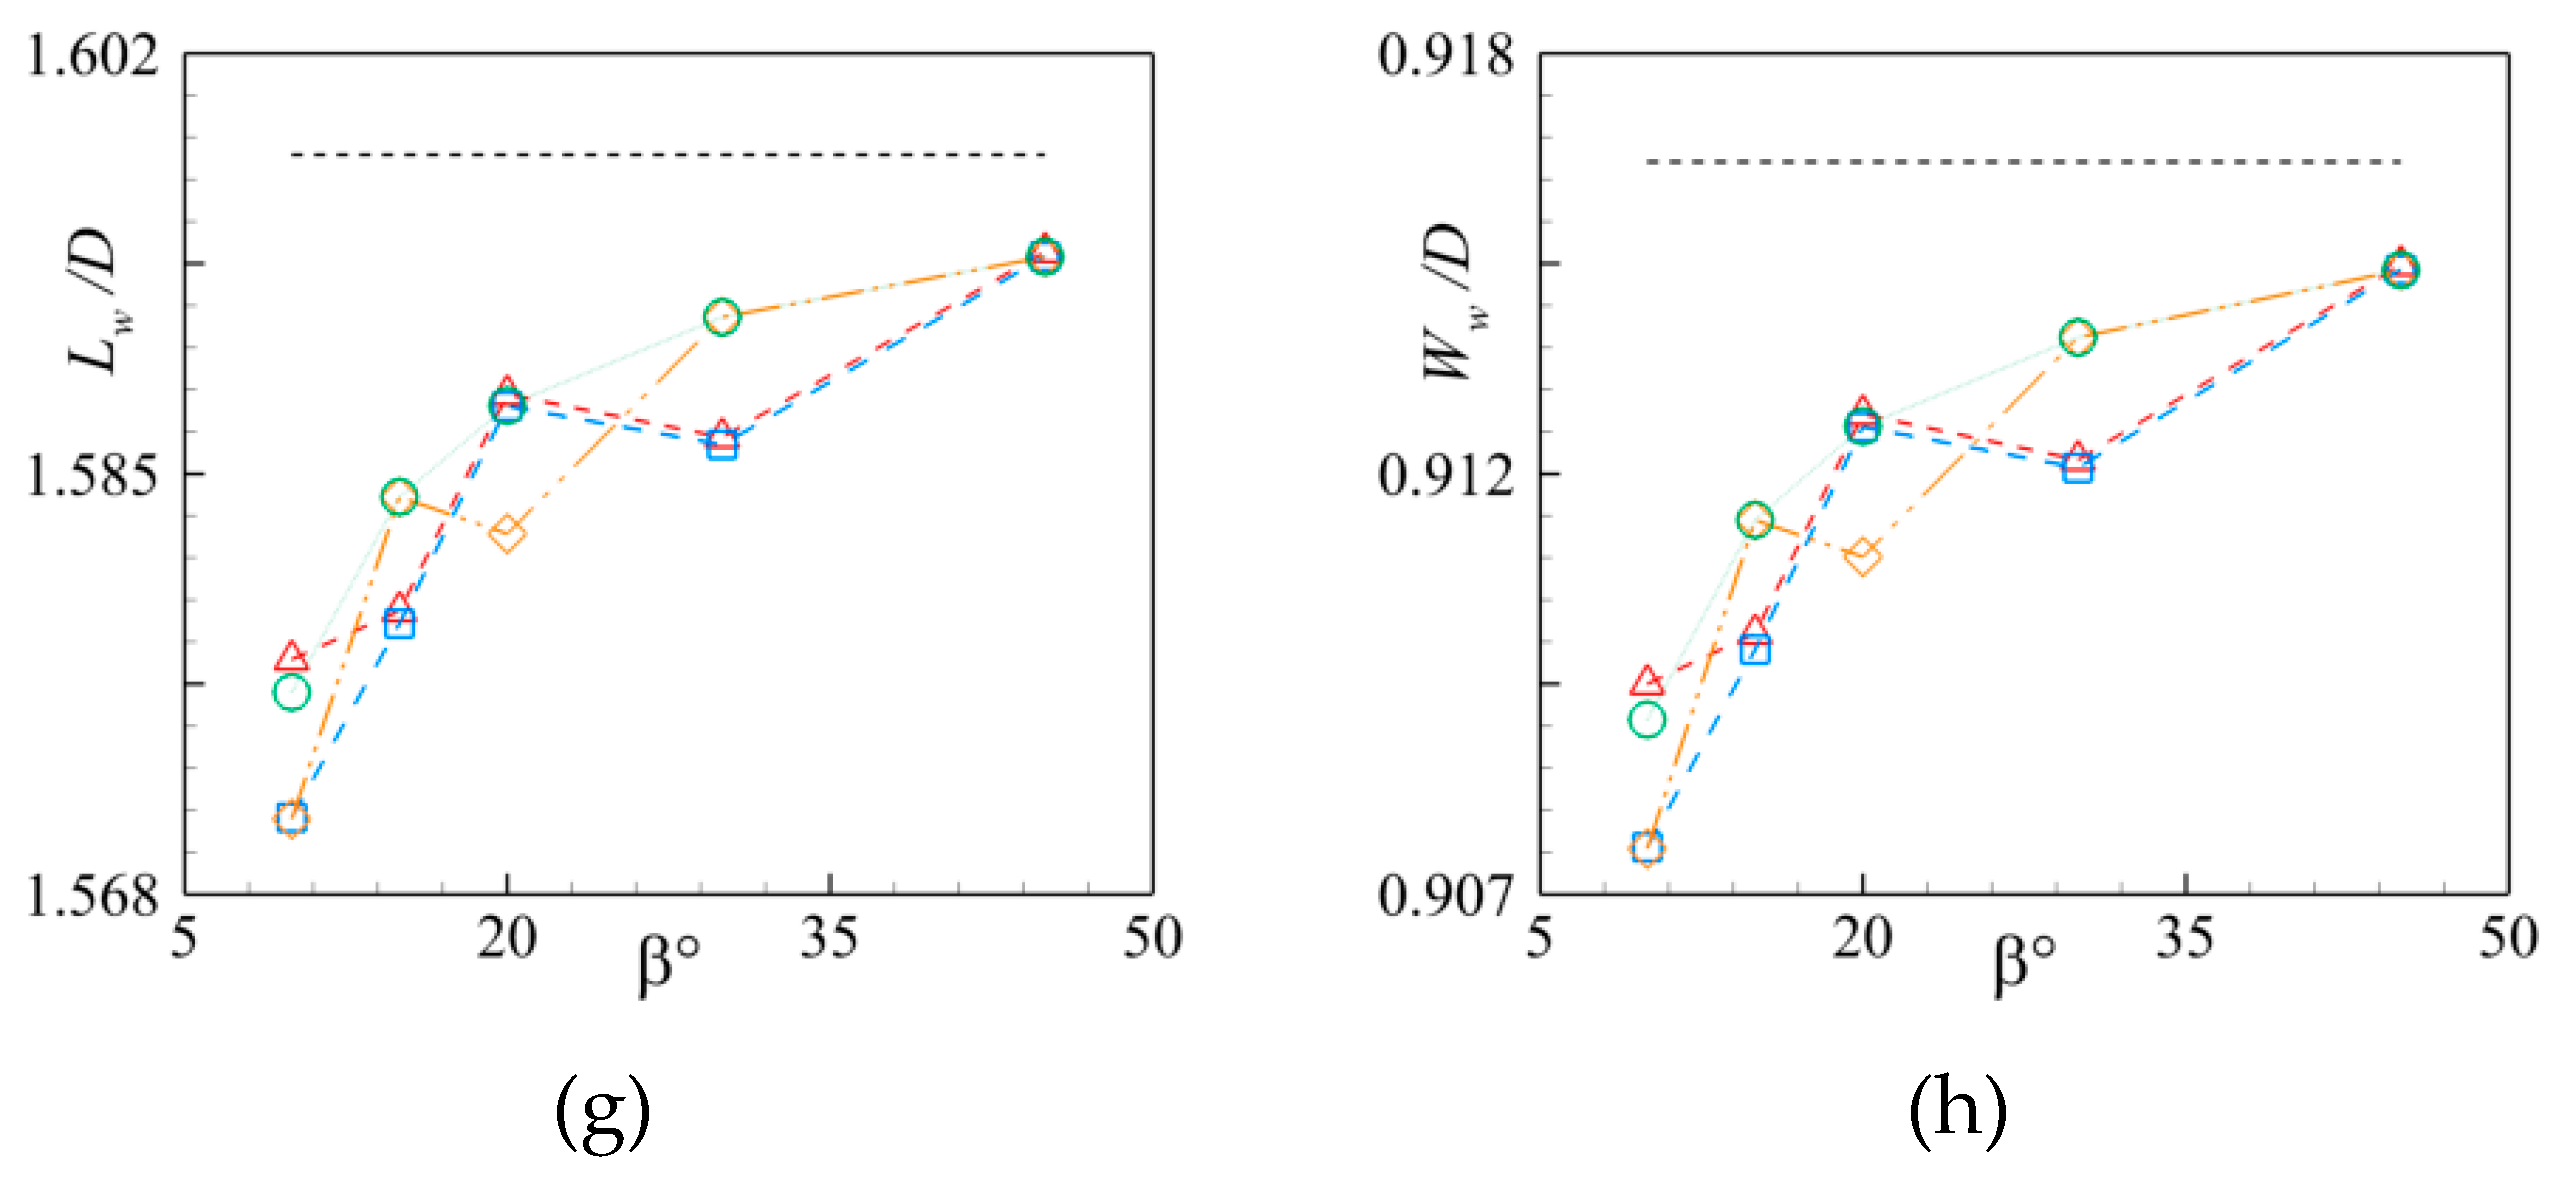
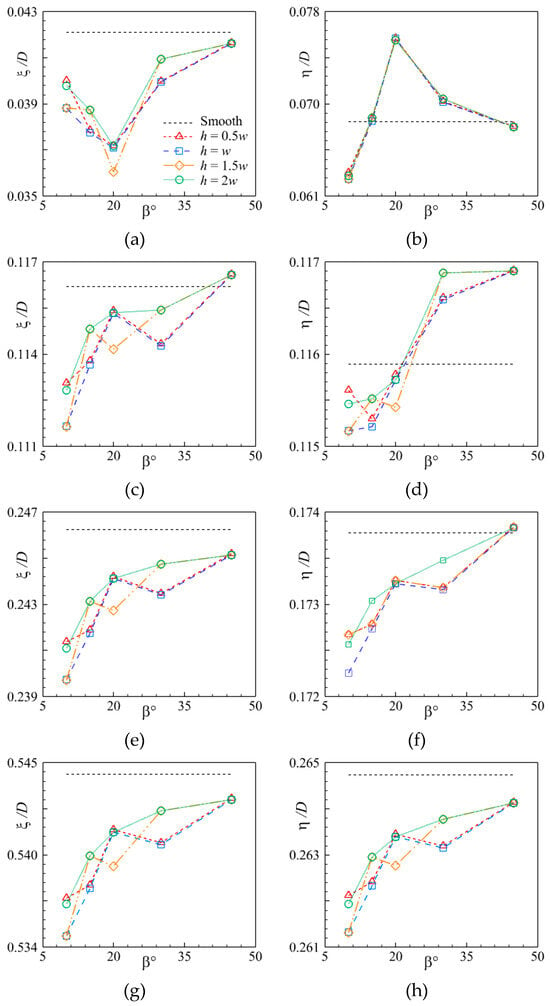
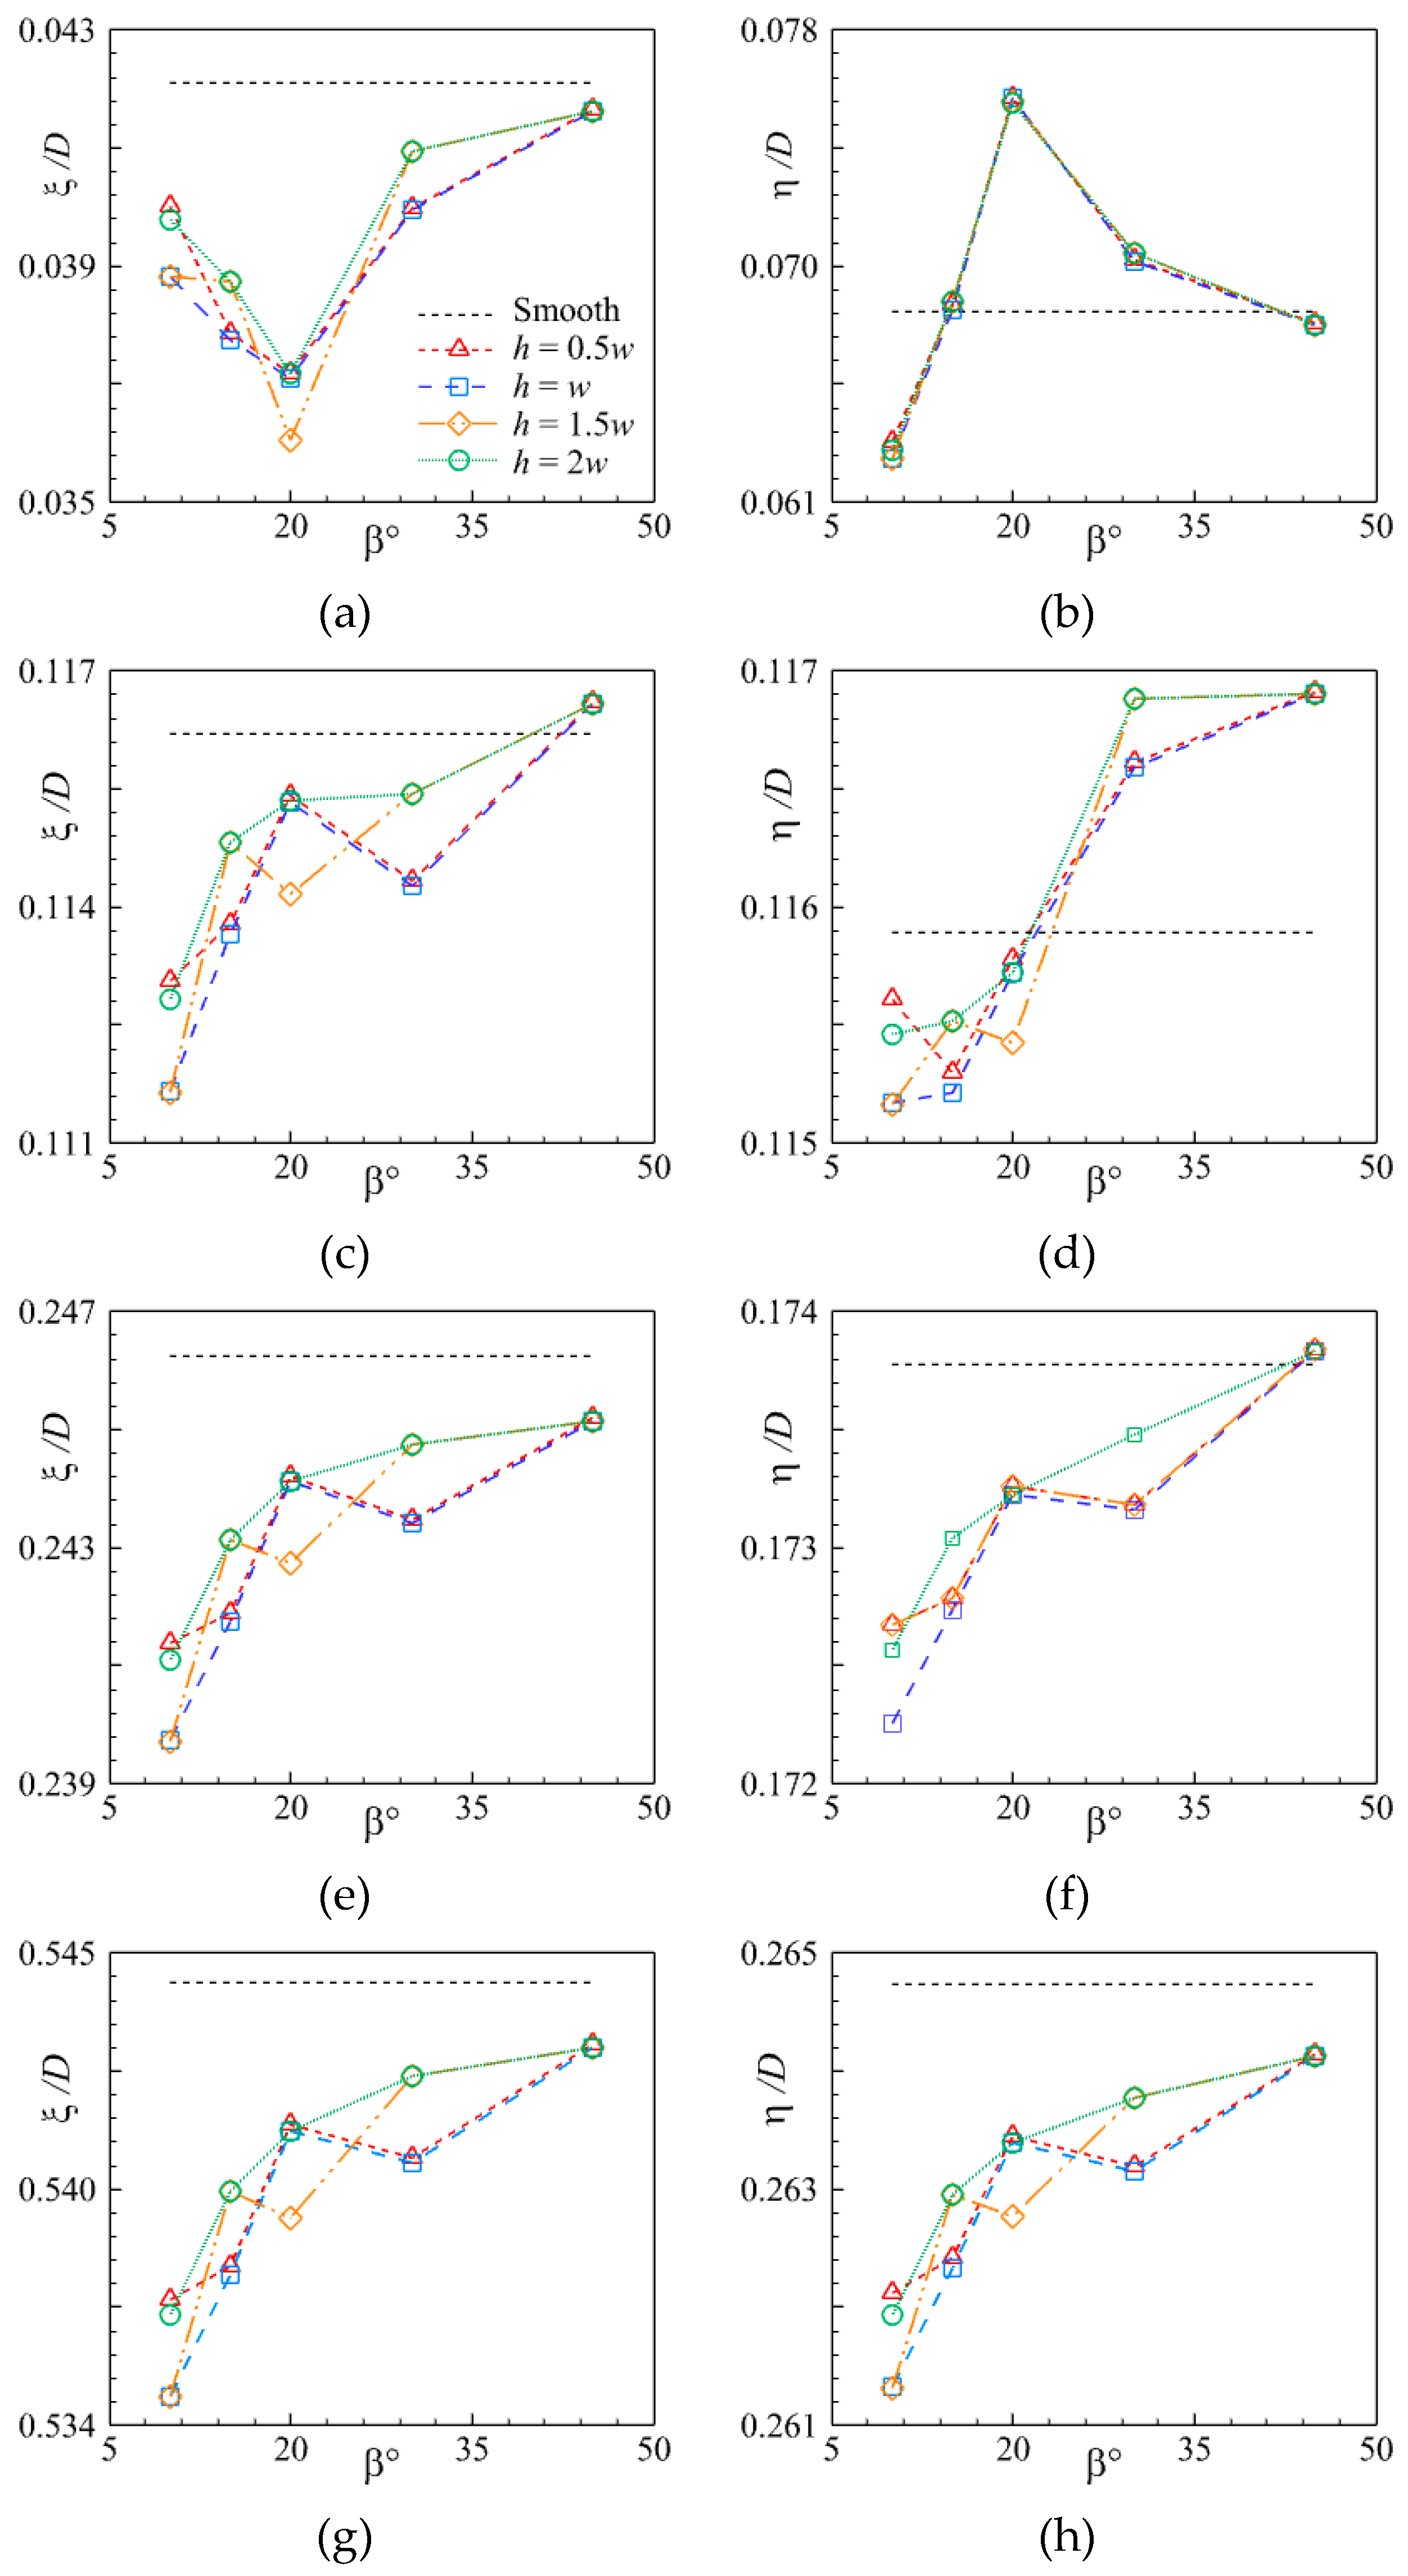
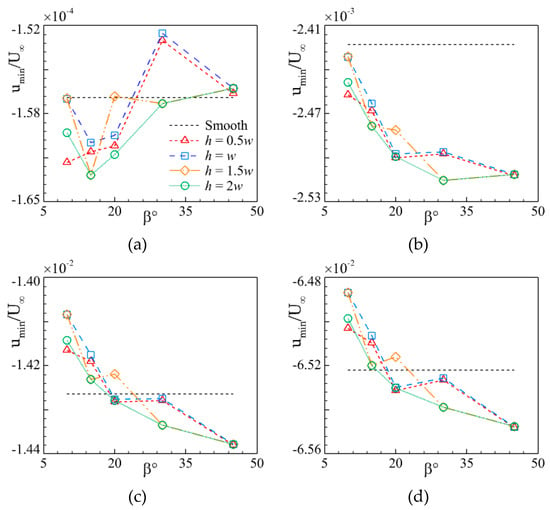
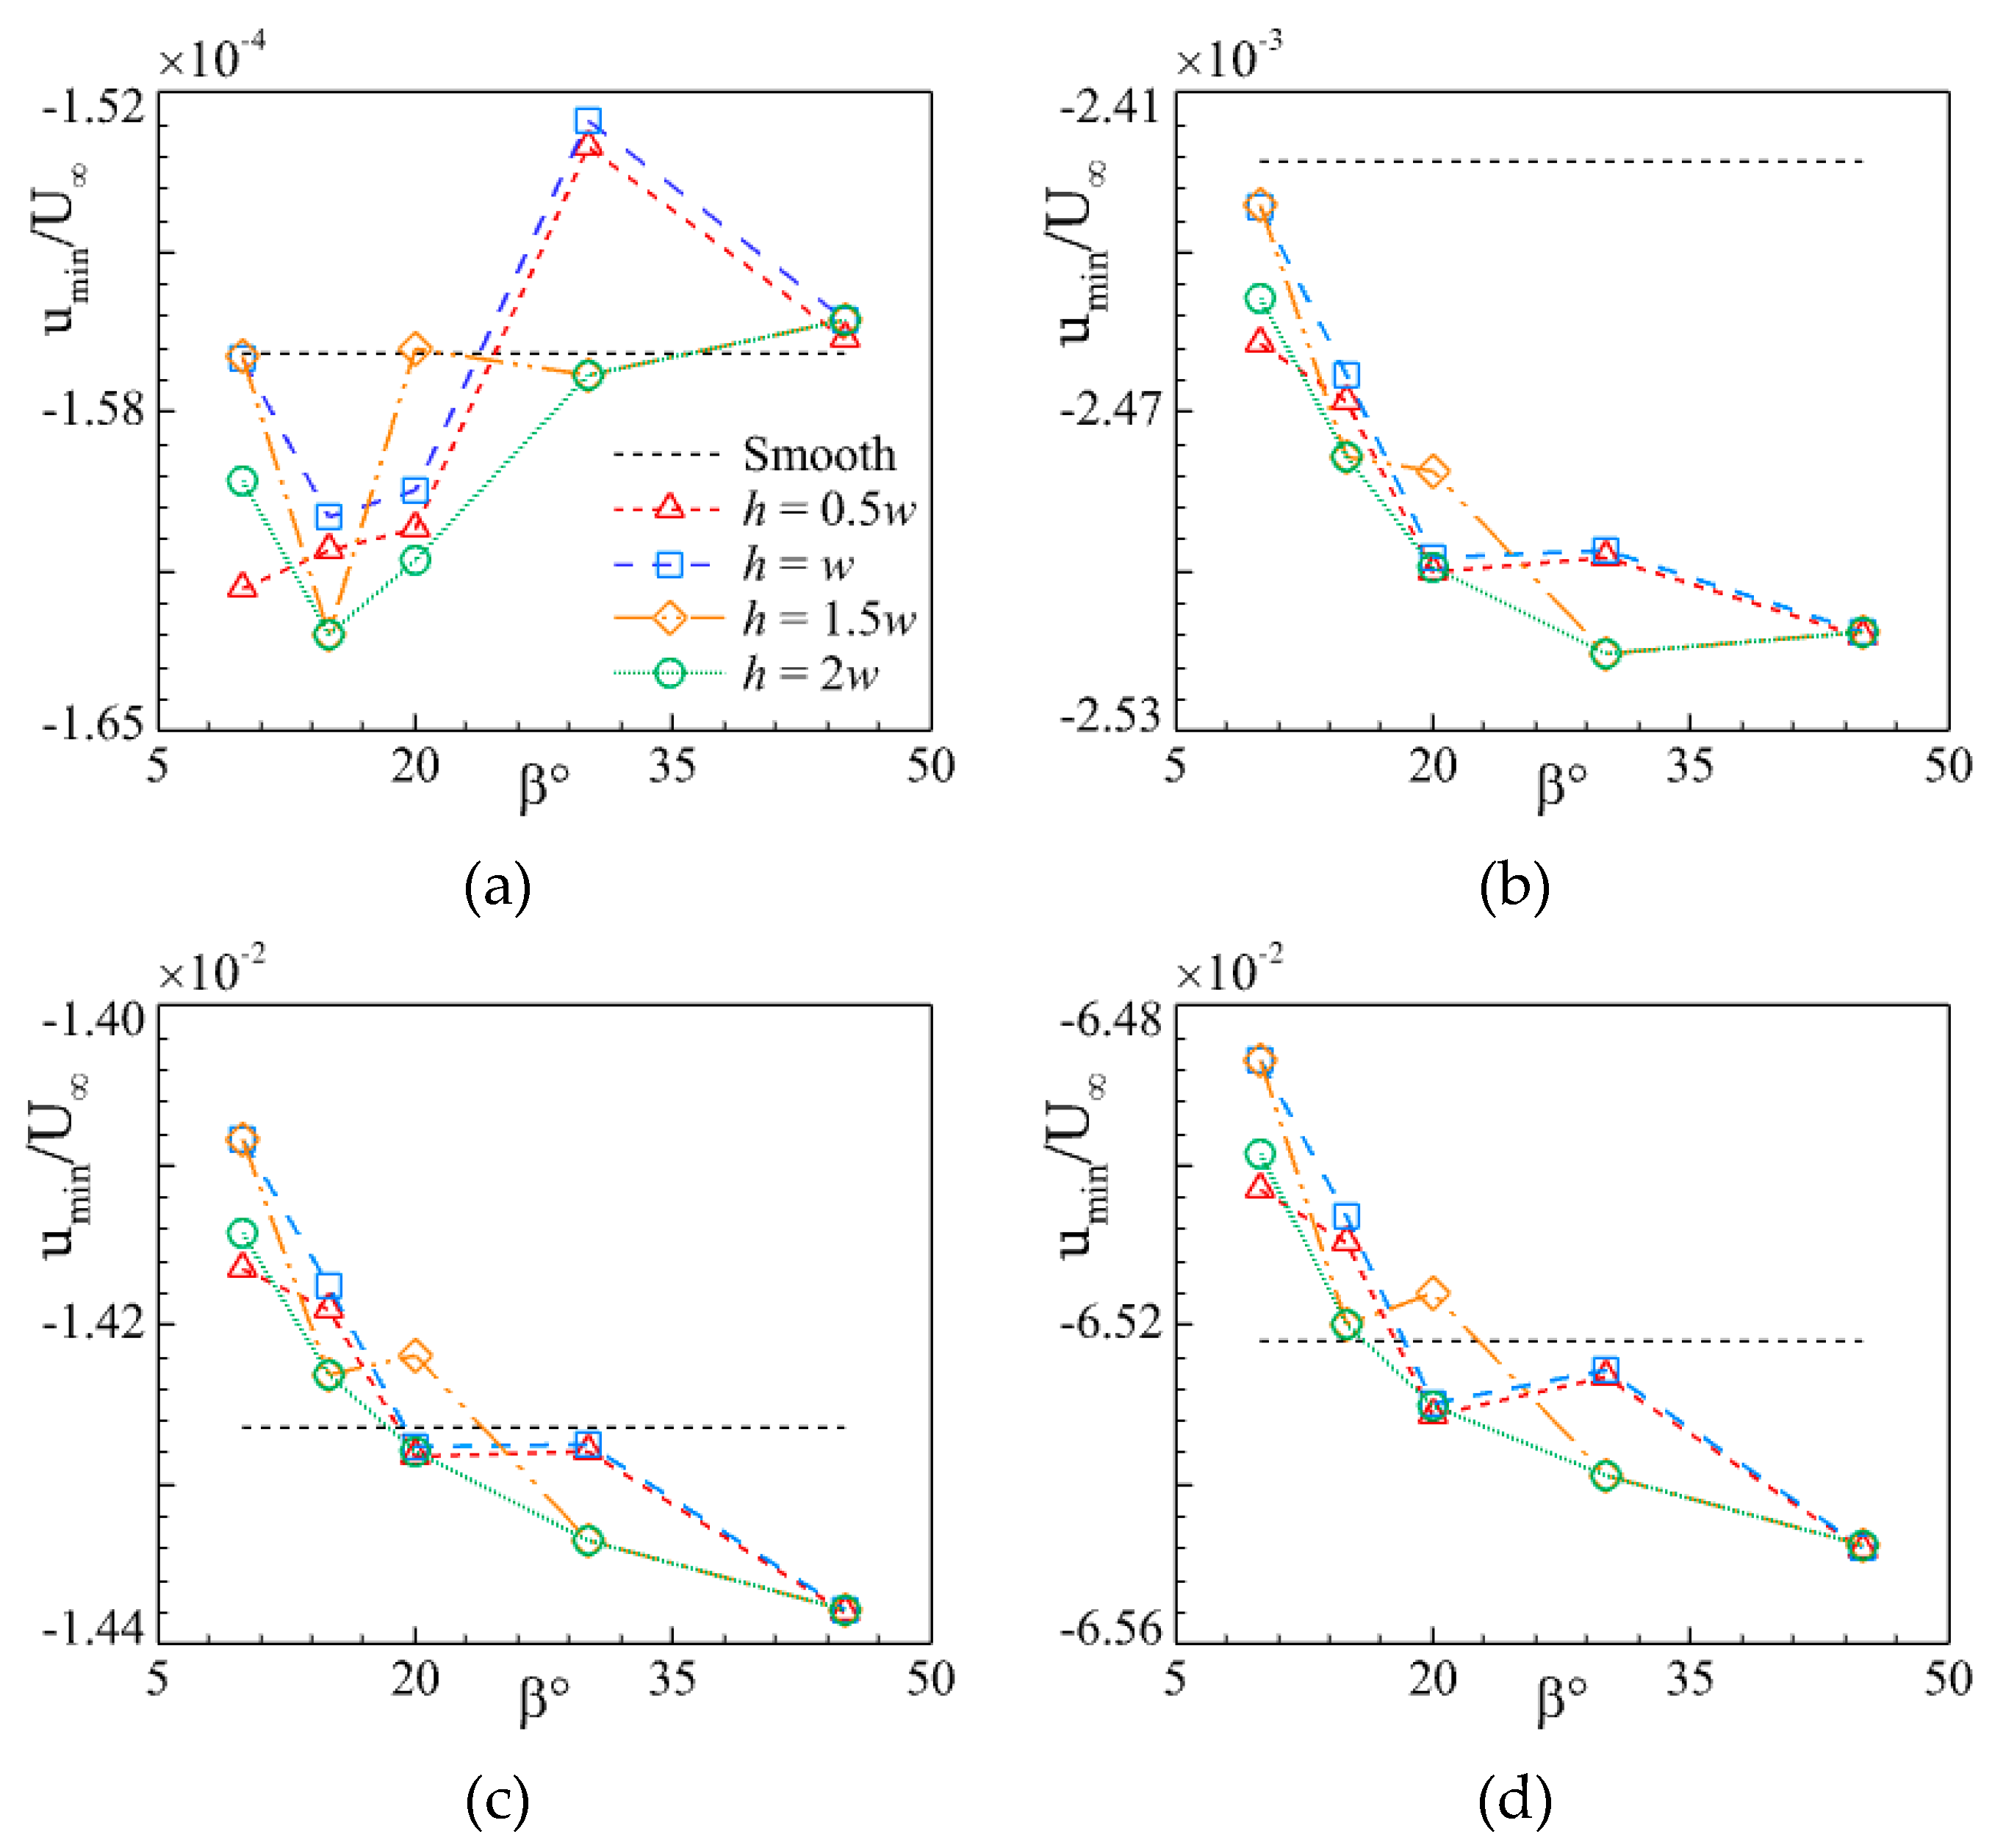
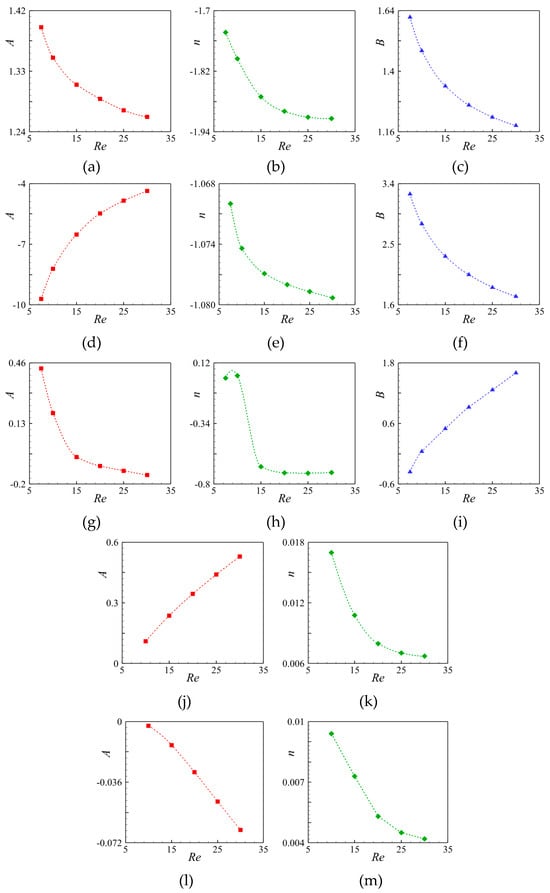
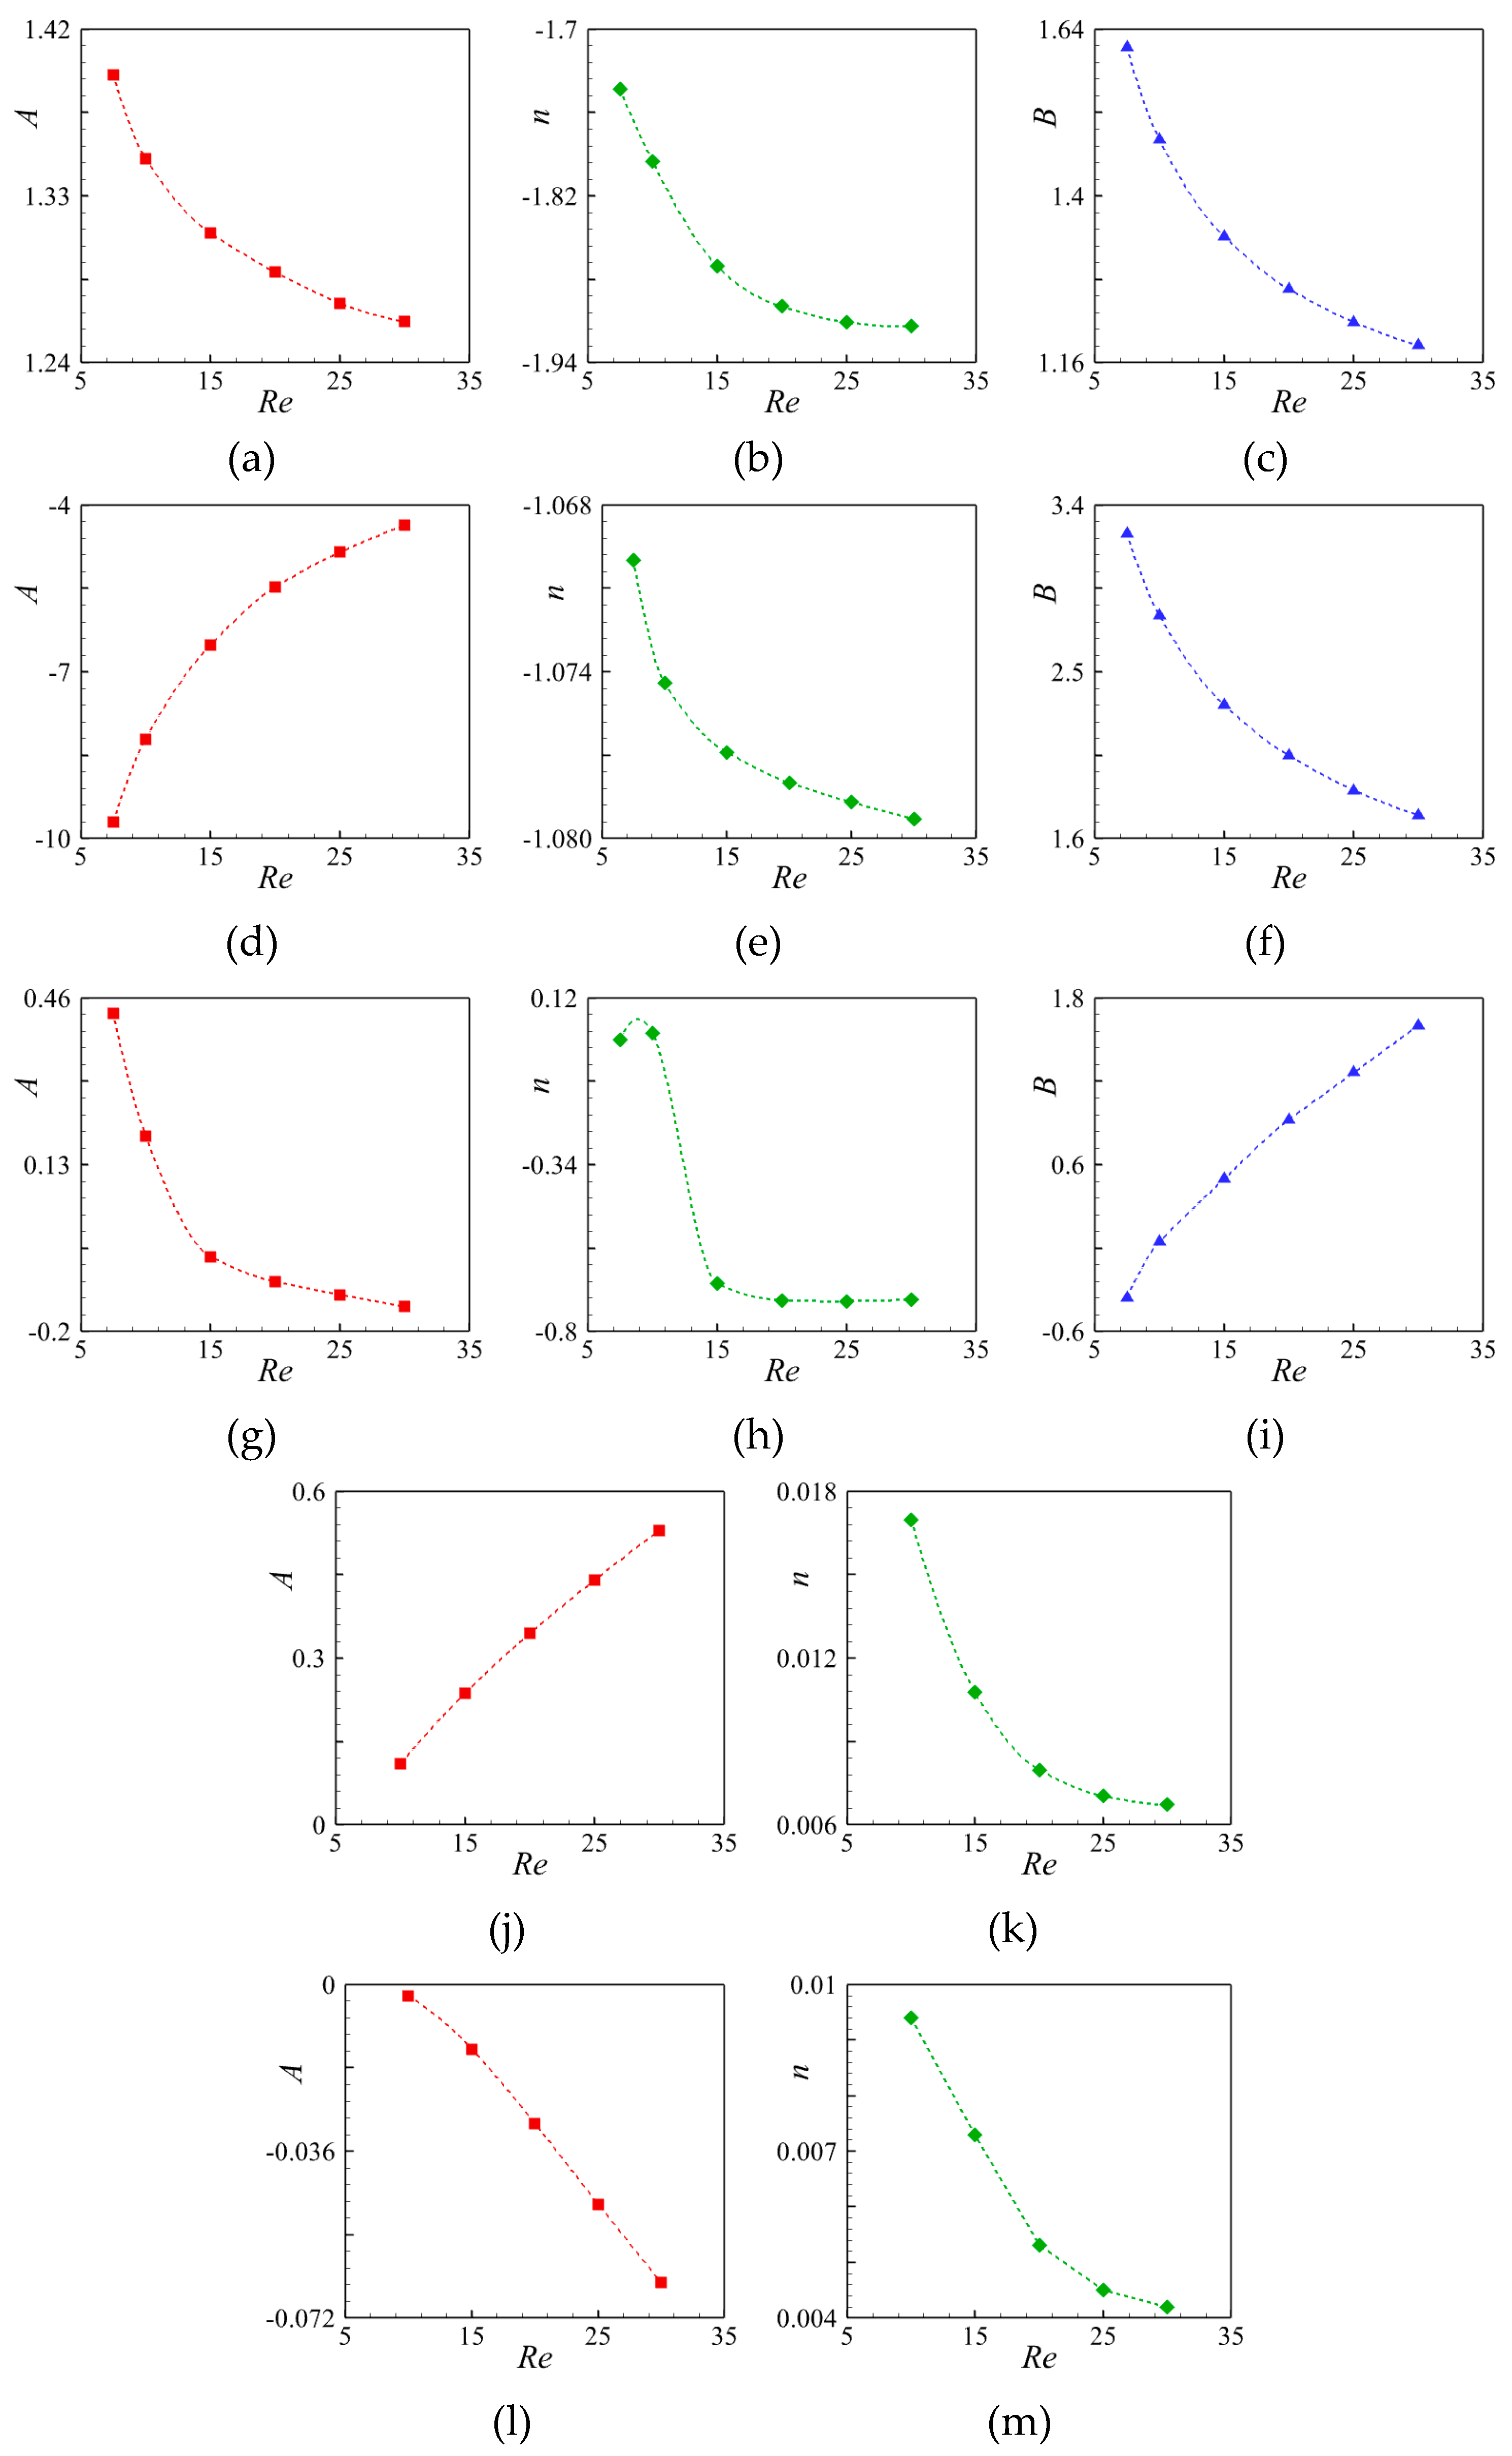
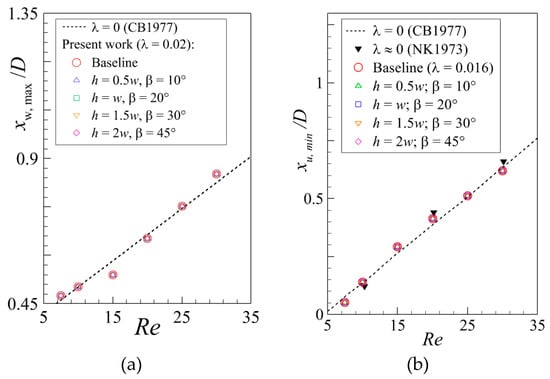

Disclaimer/Publisher’s Note: The statements, opinions and data contained in all publications are solely those of the individual author(s) and contributor(s) and not of MDPI and/or the editor(s). MDPI and/or the editor(s) disclaim responsibility for any injury to people or property resulting from any ideas, methods, instructions or products referred to in the content. |
© 2025 by the authors. Licensee MDPI, Basel, Switzerland. This article is an open access article distributed under the terms and conditions of the Creative Commons Attribution (CC BY) license.