


Highlights
This research compares two U.S. Geological Survey-developed methods, the stereo photogrammetry method, and the physics-based method with the National Oceanic and Atmospheric Administration composite band-ratio method to derive bathymetry (underwater topography) from different satellite missions (WorldView, Landsat, and Sentinel-2). All satellite derived bathymetry (SDB) methods were applied to three different areas with different environmental, water quality, and geological conditions in Puerto Rico, Florida, and Guam. For all methods, satellite missions, and sites, the SDB error distribution is generally bimodal, leading to the potential ineffectiveness of traditional error metrics such as the root mean square error (RMSE). Our results demonstrate that detrending after alignment with ICESat-2 ATL24 data transforms the error distribution to approach normality and increases the diagnostic value of error metrics.
What are the main findings?
- SDB water depth measurement capability is strongly correlated with local water quality conditions, whereas vertical accuracy is not dependent on processing methods or satellite sensor.
- Even if SDB accuracy increases when aligned with external bathymetry (e.g., ICESat-2 ATL24), in the absence of detrending, the error distribution can be bimodal irrespective of method or satellite sensor.
What are the implications of the main findings?
- SDB error metrics are not symptomatic if the error distribution is bimodal.
- SDB error bimodality has implications for change-analysis interpretation due to different biases in shallow versus deeper water.
Abstract
This research focusses on three satellite-derived bathymetry methods and optical satellite instruments: (1) a stereo photogrammetry bathymetry module (SaTSeaD) developed for the NASA Ames stereo pipeline open-source software (version 3.6.0) using stereo WorldView data; (2) physics-based radiative transfer equations (PBSDB) using Landsat data; and (3) a modified composite band-ratio method for Sentinel-2 (SatBathy) with an initial simplified calibration, followed by a more rigorous linear regression against in situ bathymetry data. All methods were tested in three different areas with different geological and environmental conditions, Cabo Rojo, Puerto Rico; Key West, Florida; and Cocos Lagoon and Achang Flat Reef Preserve, Guam. It is demonstrated that all satellite derived bathymetry (SDB) methods have increased accuracy when the results are aligned with higher-accuracy ICESat-2 ATL24 track bathymetry data using the iterative closest point (ICP). SDB vertical accuracy depends more on location characteristics than the method or optical satellite instrument used. All error metrics considered (mean absolute error, median absolute deviation, and root mean square error) can be less than 5% of the maximum bathymetry depth penetration for at least one method, although not necessarily for the same method for all sites. The SDB error distribution tends to be bimodal irrespective of method, satellite instrument, alignment, site, or maximum bathymetry depth, leading to the potential ineffectiveness of traditional error metrics, such as the root mean square error. However, our analysis demonstrates that performing detrending where possible can achieve an error distribution as close to normality as possible for which error metrics are more diagnostic.
1. Introduction
Although methods for deriving shallow-water bathymetry from satellite data have been in development for approximately five decades [1,2], the last two decades saw an exponential increase in satellite derived bathymetry (SDB) papers published, especially since the Landsat archive became freely available in 2008 [3]; Sentinel-2A in 2015 [4]; and NASA’s Ice, Cloud, and Land Elevation Satellite (ICESat-2) launched in September 2018 [5]. There is a scarcity of bathymetric data and an understanding of its real economic impact in the Island Nations in the Pacific, southeast Asia, and the Caribbean, including the U.S. and its territories. Efforts to address the need for coastal risk reduction, adaptive planning and sustainable sharing, and utilization of coastal resources, including fishing rights, rest on accurate and current topography and nearshore bathymetric data [6,7,8,9,10]. To this end, the economic aspects of SDB-derived data versus a more traditional bathymetric data collection are concisely summarized by the International Hydrographic Organization Hydrographic Surveys Working Group: “Our community continues to face a huge challenge in the available funding and resources to enable us to improve and maintain a detailed map of our seabed. SDB can make a valuable and cost-effective contribution to the endeavor in the challenging shallow coastal environments” [11].
With over 470 SDB papers published in 2025 alone (Google Scholar, keyword “satellite derived bathymetry”), and approximately 600 papers for ICESat-2 bathymetry, why SDB is a topic of interest has already been answered extensively, but at least three questions still need to be addressed: (1) Do all methods perform the same in similar environmental conditions or areas? (2) What are the limits of vertical accuracy improvement for each method? and (3) Is SDB vertical accuracy dependent on satellite mission and processing method?
Irrespective of the satellite remote-sensed data and extraction algorithm used for SDB, all can be classified into five broad fundamental categories that reference distinct basic SDB methods, each with different subcategories, advantages and limitations, and varied potential for machine learning enhancements: (1) band-ratio; (2) physics-based, using radiative transfer equation (RTE); (3) photogrammetric; (4) wave kinematics; and (5) satellite lidar (Table 1). All of these basic methods can have several different processing algorithms and hypotheses, or take advantage of relatively simple regression/equation models to relatively more complex machine-learning algorithms and artificial intelligence. All but the satellite lidar (such as ICESat-2) will derive a spatially continuous bathymetric surface.
Table 1.
Basic SDB methods and attributes. MS = multispectral, HS = hyperspectral, PAN = panchromatic, SAR = synthetic aperture radar, Sat = satellite, RMSE = root mean square error.
The majority of these methods require a measurable response from the seafloor visible in the imagery, which limits their application to relatively clear, shallow areas. In very clear waters, the achievable depth limit may approach 30 m, or approximately 1 Secchi depth. Imagery requirements can vary slightly by technique, but they typically exclude clouds and cloud shadows, ice, excessive sun glint, haze, and breaking waves. The notable exception is the wave kinematics approach, which does not require seafloor visibility in imagery, because it is based on visible surface waves.
This paper concentrates on the band-ratio method, the physics-based method, the photogrammetric method, and their fusion with the satellite lidar data. All methods will be tested in three different geographical areas with different environments, geology, underwater structure, and water optical qualities: Cabo Rojo, Puerto Rico (PR); Key West, Florida (FL); and Cocos Lagoon and Achang Flat Reef Preserve, Guam (GU).
2. Methods
2.1. Study Sites
The three chosen field sites have different water qualities and bottom structures, from lower water clarity around Key West due to fine and very fine seabed sediment with a low percentage of living stony corals to very clear waters down to depths of 25–30 m around Cabo Rojo and Cocos Lagoon, with a higher percentage of living stony corals interspaced with sand and gravel of coralline origin. The highest percentage and diversity of live stony corals is found in Cocos Lagoon and Achang Flat Reef Preserve. Key West is heavily populated with highly managed sandy beaches, mangroves, and armored shores. Cabo Rojo area is the least populated, having natural shores with sea cliffs, narrow beaches, marsh, and mangrove shorelines, whereas the majority of South Guam shorelines are heavily vegetated, with some narrow intermittent beaches, marsh areas, and small armored shores off Merizo village. These sites are further characterized below.
2.1.1. Cabo Rojo, Puerto Rico
The Cabo Rojo peninsula is situated on the southwest coast of Puerto Rico, between Bahia Salinas to the west, the Caribbean Sea to the south, and Bahia Sucia to the east (Figure 1a). The peninsula itself is made of relatively poorly consolidated Quaternary beach deposits of calcareous, volcanic, and quartz sand [12], with mangrove swamps and surface saline flats. Playa Sucia, to the south, is flanked left and right by Miocene and Oligocene poorly cemented limestone headlands overlain by calcite-cemented sandstone of possibly the Holocene age [12]. The Cabo Rojo shelf is a broad and shallow platform composed of stony reefs, and patch reefs with interspaced calcareous sand and gravel, grass, and algae [13,14]. The shelf has depths down to 25 m and is characterized by low wave-energy conditions.
Figure 1.
Study site locations and stereo imagery: (a) WorldView-3 stereo imagery for Cabo Rojo, Puerto Rico; (b) WorldView-2 stereo imagery for Key West, Florida; and (c) WorldView-3 stereo imagery for Cocos Lagoon and Achang Reef Flat Preserve, Guam.
2.1.2. Key West, Florida
The Florida Keys comprise low-lying islands composed of Pleistocene limestone, the Holocene mud islands of Florida Bay, the sandy islands west of Key West (the Marquesas and Dry Tortugas), and the ephemeral islands and rocks of the reef tract [15] (Figure 1b). Most of the Florida reef tract is composed of carbonate sand from corals and calcified algae. Key West is just a few meters above mean sea level and is underlain by Pleistocene limestone [15]. On the Atlantic Ocean side, there is a wide shelf that supports the growth of modern coral reefs, whereas, on the Florida Bay side, it is characterized by a shallow sandy shoal with scattered sea grass areas, patch reefs, and small mangroves and islands made of Holocene unconsolidated carbonate muds. The shallow bottom of the Florida Keys has very few areas of stony corals, with mostly coral sand and very fine sediment (carbonate mud) that can be easily disturbed by both consistent waves due to strong winds, and heavier traffic of cruise ships and other vessels [15]. The water clarity in Florida can also be impacted by algae (e.g., macroalgae sargassum) and particularly harmful algae outbreaks, plankton, and even sewage and other pollutants due to the State’s dense population.
2.1.3. Cocos Lagoon and Achang Reef Flat Preserve, Guam
Guam is the southmost and largest island of the Mariana Islands archipelago (Figure 1c), with the northern part consisting generally of Pliocene and Pleistocene limestone, and the southern part composed of a Miocene volcanic sequence fringed with the same northern type of Pliocene and Pleistocene limestone along the east coast [16,17]. The Cocos Lagoon is one of the two single barrier reefs in the Mariana Islands archipelago and continues to the east with the fringe and flat reefs in the Achang Reef Flat Preserve. The reefs are interspersed with sand and coral gravel; seagrass; algae, including coralline algae; and patch reefs. This area is one of the most biologically rich and diverse areas of the U.S., with over 400 coral species and more than 1,000 fish species [18,19].
2.2. Data
2.2.1. WorldView Stereo Satellite Imagery
WorldView stereo satellite imagery [20,21] was acquired from Maxar archive and downloaded from U.S. Geological Survey (USGS) Earth Explorer [22]. All sets of stereo imagery have a 2-m resolution for multispectral (MS) bands and 0.5-m resolution for panchromatic (PAN) bands, and their date of acquisition, area covered, and median stereo convergence are presented in Table 2.
Table 2.
Stereo convergence angle in degrees for the stereo imagery used. WV-2 = WorldView-2; WV-3 = WorldView-3; dates are in dd/mm/yyyy format. The WorldView imagery was acquired from the Maxar archive through USGS Earth Explorer [22].
2.2.2. Landsat Operational Land Imager (OLI) Imagery
Landsat imagery can be freely downloaded from several sources, such as USGS Earth Explorer [22] and USGS GloVis [23]. Landsat 9 [24] builds upon the capabilities of Landsat 8 [25], with improved radiometric resolution from 12-bit to 14-bit. Both satellites have the Operational Land Imager (OLI) that provides eight MS bands at 30-m resolution, a PAN band at 15-m resolution, and a Thermal Infrared Sensor (TIRS) with two bands at 100-m resolution. The specific Landsat OLI images used in this study and their date of acquisition are presented in Table 3. Although the Landsat scenes cover a larger area than the high-resolution WorldView scenes used, the bathymetric results from Landsat were restricted to the same extent as the WorldView results for direct comparison.
Table 3.
Landsat OLI imagery used; dates are in dd/mm/yyyy format. LC09 = Landsat 9, LC08 = Landsat 8. The Landsat OLI imagery was acquired from USGS Earth Explorer [22].
2.2.3. Sentinel-2 Imagery
The Sentinel-2 mission [26] includes two satellites (Sentinel-2A and Sentinel-2B) equipped with a multispectral imager (MSI) and is part of the Copernicus program, the Earth observation component of the European Union’s Space program.
The Sentinel-2 MSI samples 13 spectral bands: four bands at 10-m resolution (red (R), green (G), blue (B), and near infrared (NIR)) and six bands at 20-m resolution (four narrow bands in the vegetation red edge spectral domain, called VNIR, with ~704 nm, ~740 nm, ~783 nm, and ~865 nm; and two wider short wavelength infrared bands, called SWIR, at ~1610 nm and ~2190 nm) for applications such as snow/ice/cloud detection or vegetation moisture stress assessment [26]. The Sentinel-2 images used for this work and dates of acquisition are listed in Table 4.
Table 4.
Sentinel-2A (S2A) and Sentinel-2B (S2B) imagery used for the three study sites; dates are in dd/mm/yyyy format. The Sentinel-2 images were acquired from the Registry of Open Data on AWS (2025).
2.2.4. ICESat-2 Data
NASA’s Ice, Cloud, and Land Elevation Satellite (ICESat-2) [5], launched in September 2018, has an Advanced Topographic Laser Altimeter System (ATLAS) photon-counting lidar with a visible green (532 nm) laser, which is the same wavelength as the majority of aerial bathymetric lidar instruments. The ATLAS has three left/right pairs of spots that trace six ground tracks with a repeat revisit time of 91 days. The left/right spots within each pair are approximately 90 m apart across track, with ~ 2.5 to 3.0 km distance between pairs. The along track sampling interval is ~ 0.7 to 1.0 m in the original photon-level ATL03 products for a 10 kHz pulse repetition rate and footprint size of the laser on the ground of ~13 m along track [5].
The main ICESat-2 science objectives focused on monitoring the cryosphere, with secondary goals targeting vegetation structure. Bathymetry was not an original mission requirement, but the use of a green laser gave ICESat-2 an unprecedented capability to measure shallow bathymetry in both fresh and saline waters. Multiple studies confirmed that maximum depth penetration for ICESat-2 could exceed 40 m in very clear waters (~1 Secchi depth), with a vertical accuracy of less than 0.5 m [27,28]. Because of the bathymetric capabilities, NASA is currently supporting new Level-3a data products focused on along-track bathymetry extraction in both inland waters with the designation ATL13 [29] and ocean coastal areas ATL24 [30]. ICESat-2 data are freely available to users and have a near global coverage from 88 degrees South to 88 degrees North latitude, and the revisit frequency guarantees opportunities for bathymetric observations for frequent turbid coastal areas. Although ICESat-2 data lack spatial resolution between tracks, they are dense along tracks, and thus they are highly complementary and easy to integrate within workflows to derive bathymetry from satellite multispectral imagery.
The newly developed ICESat-2 coastal and nearshore along-track bathymetric product (ATL24) offers global photon-level classification in agreement with the American Society of Photogrammetry and Remote Sensing (ASPRS) lidar aerial survey (LAS) classification standards [28]. The elevation of sea surface (class 41) and refraction-corrected seafloor (submerged elevation, class 40) can be retrieved in both ellipsoid and orthometric heights (Earth Gravitational Model EGM2008) [30]. Each ATL24-classified point has classification confidence intervals and per-point uncertainty estimates. ICESat-2 data, including ATL24, can be downloaded using the NASA SlideRule [31] real-time science data-processing service.
2.2.5. Lidar Data
Cabo Rojo, Puerto Rico
Two different post-Hurricane Maria topographic–bathymetric digital elevation model (TBDEM) lidar datasets were used, one acquired in 2018 [32], and one collected in 2019 [33] to fill in the gaps of previous surveys.
The topography of the 2018 lidar data [32] was used exclusively for topographic alignment of the photogrammetry method results because this method generates a TBDEM, and the 2019 bathymetric lidar [33] was used for validation for all three SDB method results discussed here. The topo-bathymetric lidar data acquisition from 2018 contains classified topography and bathymetry lidar data using the Coastal Zone Mapping and Imaging Lidar (CZMIL) system. CZMIL integrates a lidar topo-bathymetric sensor, a digital camera, and a hyperspectral imager on a single remote-sensing platform. The CZMIL topographic data have a vertical RMSE of 0.099 m, and the bathymetric data vertical root mean square error (RMSE) respects the International Hydrographic Organization (IHO) standards and is between 0.100 and 0.255 m for depths between 0 and 30 m, increasing with depth [32].
The NOAA 2019 topo-bathymetric lidar data were collected using a Riegl VQ-880-G II sensor between 20 January 2019 and 2 June 2019. The reported topographic bare-earth (non-vegetated) vertical RMSE is 0.086 m, corresponding to the ASPRS Positional Accuracy Standards for Digital Geospatial Data [34] for a 10-cm RMSEz Vertical Accuracy Class, and 0.128 m for vegetated areas. The reported bathymetric vertical RMSE for shallow-water bathymetry is 0.121 m [33], in accordance with an 18.5-cm RMSEz Vertical Accuracy Class [34].
Key West, Florida
NOAA Hurricane Irma supplemental topo-bathymetric lidar data were collected between 11 November 2018 and 23 March 2019 to enable accurate and consistent measurement of the national shoreline and to provide a regularly updated and consistent national shoreline to define America’s marine territorial limits and manage coastal resources, using three Riegl systems: a VQ-880-G+, a VQ-880-GII, and a VQ-880-GH [35]. Submerged topographic elevations were adjusted to correct for sensor-depth bias on a per-sensor basis using NOAA-provided ground truth data. The bathymetry was validated against 509 submerged check points within a 1 m depth, with an RMSE of 0.056 m [36]. The bare-earth topography’s vertical RMSE values are 0.043 m and 0.084 m for vegetated areas [36]. All vertical RMSE values for the survey are within the specifications of the National Coastal Mapping strategy 1.0 from 2018 [37].
Cocos Lagoon and Achang Reef Flat Preserve, Guam
The topo-bathymetric lidar for Guam was collected between 20 January 2020 and 13 July 2020 for the Typhoon Yutu supplemental mapping, Guam, and the Commonwealth of the Northern Marianas Islands (CNMI) to provide a regularly updated and consistent national shoreline for United States of America’s marine territorial limits and to manage coastal resources [38]. The lidar survey was performed using a Leica Chiroptera 4X (CH4X) laser system dually mounted with an additional Leica 40kHZ deep bathymetric channel known as a Leica HawkEye 4X (HE4X). Besides the green lidar instrument (532 nm) capable of both topographic and bathymetric surveys, an integrated NIR laser (1064 nm) instrument was incorporated to add additional topographic data. For the overall project, the lidar bare-earth vertical RMSE is 0.047 m, 0.192 m for vegetation, and 0.119 m for shallow bathymetry [39]. Similar to the data for Florida Keys, the topography part of the lidar data was used to align the satellite-derived topography where appropriate, and the bathymetry part was used for validation only.
2.3. Satellite-Derived Bathymetry Methods
This paper will use results from NOAA SatBathy method [40] based on the band-ratio algorithm applied to a composite Sentinel-2 multispectral satellite imagery using a simplified calibration, followed by ICESat-2 ATL24 calibration, the physics-based method (PBSDB) [40] based on the radiative transfer equation (RTE), using Landsat imagery; and the photogrammetric method [41], using NASA Ames stereo pipeline (ASP) SaTSeaD module, using PAN and MS Maxar WorldView stereo imagery. ICESat-2-derived bathymetry (ATL24) is used for SDB alignment to increase the bathymetry’s vertical accuracy when ATL24 data are more accurate than the other SDB results. All bathymetric vertical error statistics are calculated relative to aerial lidar-derived bathymetry that have the highest reported accuracy.
Because the photogrammetric method derives a continuous TBDEM and the initial lidar used is also a TBDEM, all topographic heights are positive up, and all bathymetric depths are negative down (as actual bottom heights under water) in orthometric heights throughout this paper.
2.3.1. Composite Image Band-Ratio Method: SatBathy
The NOAA SatBathy tool was developed for rapid reconnaissance and interim chart updates, as stated by the Nautical Chart manual [42]: “Satellite Derived Bathymetry (SDB) may be used to revise waterways on nautical charts that have not been recently surveyed by acoustic means, such as MBES (multibeam echosounder), or by Airborne Lidar Bathymetry (ALB) and/or are economically/strategically impractical to survey, such as extremely remote or highly dynamic areas. The use of SDB data is especially useful where vessel traffic or the deployment of aids to navigation indicate that charted data is misleading and there are no recent surveys to update the chart.”
SatBathy offers a graphical interface that facilitates a connection to [43] to inspect and download Sentinel-2 imagery suitable for the area of interest. For all selected images, a non-water mask is applied using an empirical threshold of 0.05 for the Sentinel-2 SWIR1 top-of-atmosphere (TOA) reflectance [44,45]. The algorithm is based on two ratio models using the natural logarithm of the remote-sensing reflectance (Rrs, sr−1) of the blue band (490 nm) to the red band (664 nm) (), and the blue band (490 nm) to the green band (560 nm) () [46]. The log-transform is used to account for the exponential decay of light with depth, and both models calculate bathymetry pseudo-depth and band-ratios (, , ) rasters considered a proxy for real bathymetric depth.
To minimize the impacts of turbidity, multiple scenes are processed to calculate and for each [46,47]. The maximum value for each log ratio per pixel is selected across all scenes to derive a composite raster, assuming maximum values are the least affected by shoaling or turbidity. A switching rule is applied to blend the two and composite results for improved accuracy across both shallow and deeper regions as follows [40]:
was determined by the following linear weighting formula [40]:
The new blended composite result is calibrated to true depths in meters according to the calibration equation below:
where m1 is the regression line slope representing the rate of change in SDB with respect to ; and is the intercept, the value of when = 0.
The NOAA SatBathy tool initially uses a simplified calibration procedure for rapid calculation in which an approximate m1 is assigned based on regional average water quality and m0 is selected by interactively sampling a nearshore pixel at the land–water interface using the SatBathy graphical tool. These initial calibrated results are further refined to add both measurement units (usually meters) and increase the vertical accuracy by using external high vertical accurate bathymetric data (e.g., lidar, sonar, ICESat-2 ATL24, etc.). Here, the final calibration was refined with ATL24 data, such that only five random selected points per each 1-m depth of available ATL24 data were used. This stratified sampling was designed to minimize depth-dependent imbalance in the reference data (i.e., creating a fit skewed towards either shallow- or deep-water data points) and reserved the rest of the ICESat-2 ATL24 data for further alignment.
Finally, NOAA’s Vertical Datum Transformation tool (VDatum) [48] can be used to vertically transform the SDB results to the desired vertical reference frame. The overall SatBathy methodology is presented in Figure 2.
Figure 2.
SatBathy methodology diagram.
2.3.2. Physics-Based Method: PBSDB
The results considered in this paper are derived using the methodology described in [40], and this paper uses a sequence of ocean optics equations derived from radiative transfer theory and global bottom spectral library to solve for water depth when the satellite imagery is radiometrically corrected. The estimation of water optical properties (phytoplankton, dissolved organic matter, suspended solids) is obtained from optically deep-water pixels in the imagery, and, in turn, it provides the diffuse attenuation coefficient spectrum. This, together with the atmospheric correction, is used in the ocean optical reflectance equation to solve for the bottom reflectance and water depth, becoming a pixel-by-pixel inversion problem. Because the initial choice of bottom reflectance is critical, this method uses an eigenvector analysis to estimate unknown site-specific bottom reflectance jointly with a global bottom reflectance library. A generalized schematic for the method is presented in Figure 3.
Figure 3.
Schematic of the PBSDB methodology following Kim et al. (2024) [40]; MAE = mean absolute error; RMSE = root mean square error; Red, green and blue reflectance scatterplot colors refer to red, green and blue bands, respectively.
2.3.3. Photogrammetry: NASA ASP Satellite Triangulated Sea Depth (SaTSeaD) Module
The SaTSeaD bathymetric module is implemented into the NASA Ames Stereo Pipeline (ASP) open-source software (version 3.6.0) [41]. NASA ASP was developed in the late 1990s for Mars Pathfinder, and other planetary orbiters were added beginning in 2008. In principle, any sensor with rational polynomial coefficient (RPC) camera models can be processed, and in 2012, the first commercial stereo rigorous camera model was added for DigitalGlobe (now Maxar) stereo imagery. Since then, other rigorous camera models were added, such as Skysat stereo and video [49,50], Pleiades and Neo Pleiades [51], USGS Community Sensor Model (CSM) Frame [52], Synthetic Aperture Radar (SAR) [53], and PeruSat-1 [54].
The SaTSeaD module derives a seamless continuous TBDEM and uses stereo MS green (or blue) bands for relatively deeper water penetration and stereo PAN bands for very shallow waters (usually down to 5-m depth) and the topography part of the TBDEM because the PAN-derived results are more accurate. The SaTSeaD general steps consist of four steps: (1) generating a land/water mask; (2) water elevation calculation; (3) stereo triangulation; and (4) generating topo/bathy/topo-bathymetric 3D point clouds and digital surface models (DSMs) (Figure 4).
Figure 4.
Generalized methodology diagram outlining the main steps of the SaTSeaD bathymetry module. MS = multispectral, PAN = panchromatic, and NIR = near-infrared.
The land/water mask is necessary in both the calculation of the water elevation and for knowing where the Snell’s law of refraction needs to be applied during triangulation [41]. The water surface elevation depends on the date and time of the stereo image acquisition, as well as location, and it is critical to determine at what height the light rays are refracted at the triangulation stage to obtain correct bathymetric heights. The bathymetry triangulation stage requires, in addition to the land/water mask and the water surface elevation, a known refraction coefficient. When the SaTSeaD module is used, the main steps of the stereo reconstruction before the triangulation stage are the same as for the traditional ASP topography reconstruction, with the same available parameters (image alignment, correlation, sub-pixel refinement, and filtering). Only the triangulation stage is different, because the ray trajectories remain undisturbed over land but refract at the water surface according to Snell’s law. This software design enables the seamless derivation of TBDEM surfaces in a single process which facilitates the increase in bathymetric vertical accuracy when the TBDEM is alighted to high-accuracy topographic data only, because the TBDEM is a rigid surface.
2.3.4. Alignment with External High-Accuracy Topography or Bathymetry
Theoretically speaking, any three-dimensional (3D) data (e.g., point cloud and elevation raster) can be aligned with different 3D data for georeferencing, but to increase accuracy, the reference data (data to align with) should be more accurate (usually at least one order of magnitude) than the data to be aligned. It is important to note that the SDB accuracy will never be better than the reference data used in alignment. There are several different algorithms for data alignment, each with various constraints, but all at least will estimate a rotation and translation to register one data to the other by concomitantly minimizing the mean square distance between them. Because the alignment transform is usually a rigid combination of rotation and translation parameters in three dimensions, most of the time, these methods do not solve for a scale change.
NASA ASP implements a few of the most common alignment strategies, such as the following:
- (1)
- Iterative closest point (ICP) [55] with two flavors: point-to-plane ICP that can accommodate larger translations of several hundred to a thousand meters, and point-to-point ICP that is more acceptable to smaller translations.
- (2)
- Nuth and Kaab algorithm [56] that can be sub-grid-size accurate, but is stricter in initial assumptions. For example, the algorithm requires substantial overlap between the reference and 3D data to be aligned, and no rotation relative to each other (in other words, it computes only a translation transform, but no rotation transform);
- (3)
- Fast Global Registration algorithm [57] is suitable for small translations, but it is relatively robust to a large percentage of outliers because it does a cross-check;
- (4)
- Feature-based alignment can accommodate both large translations and changes in the scale factor, but most of the time, its resultant transform matrix is used as an initial starting point for a subsequent alignment method that is more accurate [58].
Both the SatBathy and the PBSDB methods derive only bathymetry, whereas the NASA ASP with SaTSeaD module delivers an integrated seamless and rigid TBDEM surface. Although all three methods can take advantage of external high-accuracy bathymetric data (e.g., ICESat-2 ATL24) to improve SDB accuracy, only SaTSeaD results can be aligned with external high-accuracy topographic data to increase both the topography’s and bathymetry’s vertical accuracy. The bathymetric lidar data will be used exclusively for SDB validation.
Because ICESat-2 ATL24 bathymetric data can be dense along tracks, but lack spatial resolution between tracks, the most adequate alignment algorithm was determined to be ICP point-to-point 3D translations. Usually, the SDB results are either in ellipsoid heights or in orthometric heights, depending on the method used, whereas ATL24 can be downloaded in ellipsoid or EGM2008 orthometric heights. For the contiguous U.S. and territories, it is recommended to use ATL24 in ellipsoid heights because EGM2008 is not an accurate datum, and use the NOAA VDATUM [48] tool to obtain a correct vertical datum transform when necessary. Here, all ATL24 bathymetric data were converted from ellipsoid heights to orthometric heights NAVD88 using VDATUM. All SDB data were ICP-aligned (translation only) with ATL24 bathymetric data to investigate if the alignment increases the SDB vertical accuracy (minimizes error metrics), including the SatBathy results, irrespective of their prior ICESat-2 ATL24 calibration on randomly selected points. In the case of the SatBathy results, the additional improvement after ATL24 alignment is posited to be minimal.
3. Results
For Cabo Rojo, the depth penetration (alias maximum bathymetric height in orthometric) is approximately −25 m, with the physics-based method reaching −28 m, whereas for Key West, the maximum depth penetration barely exceeded a depth of −7 m. In Cocos Lagoon and Achang Reef Flat Preserve, the maximum depth achieved varies somewhat with the method used, −25 m for the stereo SaTSeaD, and −28 and −30 m for SatBathy and physics-based methods, respectively.
The SDB horizontal resolution matches the initial horizontal resolution of the satellite sensor’s respective MS bands used in deriving bathymetry. All initial SDB results (three methods three sites), as well as the ATL24-aligned results, were validated against bathymetric lidar grided to the same resolution as the validated data. In the case of the stereo SaTSeaD results, two further alignments on topography using lidar and ICESat-2 ATL06 topographic data were performed to explore if this type of alignment increases the bathymetric accuracy (decrease error statistics) and if it is influenced by the percent of topographic area available in the TBDEM surface. The bathymetry DEMs; the location of ICESat-2 ATL24 and ATL06 data, where appropriate; the satellite sensor used for each method; and the validation error violin plots are presented in Figure 5 for Cao Rojo, Figure 6 for Key West, and Figure 7 for Cocos Lagoon and Achang Reef Flat Preserve.
Figure 5.
Satellite-derived bathymetric digital elevation models for Cabo Rojo, Puerto Rico, using stereo SaTSeaD (a), physics-based (b), and SatBathy (c) methods, and their respective error distribution with box-and-whisker plots (right column). Pink points = ICESat-2 ATL24 bathymetric points; orange points = ICESat-2 ATL06 topographic points; mil = million; k = thousands; KDE = kernel density estimate. (Note: KDE is not constrained to the range [0, 1].)
Figure 6.
Satellite-derived bathymetric digital elevation models for Key West, Florida, using stereo SaTSeaD (a), physics-based (b), and SatBathy (c) methods, and error distribution with box-and-whisker plots (right column). Pink points = ICESat-2 ATL24 bathymetric points; orange points = ICESat-2 ATL06 topographic points; mil = million; k = thousands; KDE = kernel density estimate. (Note: KDE is not constrained to the range [0, 1].)
Figure 7.
Satellite-derived bathymetric digital elevation models for Cocos Lagoon and Achang Reef Flat Preserve, Guam, using stereo SaTSeaD (a), physics-based (b), and SatBathy (c) methods, and their respective violin plots and error statistics (right column). Pink points = ICESat-2 ATL24 bathymetric points; orange points = ICESat-2 ATL06 topographic points; St. Dev = standard deviation; MAE = mean absolute error; RMSE = root mean square error; mil = million; k = thousands; KDE = kernel density estimate. (Note: KDE is not constrained to the range [0, 1].)
Validation error statistics for data without initial outliers, percent outliers and the minimum positive and maximum negative outlier values for all methods without and with different alignments for Cabo Rojo, Key West, and Cocos Lagoon and Achang Reef Flat Preserve are presented in Table 5, Table 6, and Table 7, respectively.
Table 5.
Validation error statistics for Cabo Rojo, Puerto Rico (PR). Max. = maximum; St. Dev. = standard deviation; MAE = mean absolute error; MAD = median absolute deviation; RMSE = root mean square error; % Out. = percent outliers; −Out.< = negative outliers smaller than; +Out.> = positive outliers greater than; % RMSE+ = percent decrease for RMSE when satellite-derived bathymetry is aligned with external data.
Table 6.
Validation error statistics for Key West, Florida (FL). Max. = maximum; St. Dev. = standard deviation; MAE = mean absolute error; MAD = median absolute deviation; RMSE = root mean square error; % Out. = percent outliers; -Out.< = negative outliers smaller than; +Out.> = positive outliers greater than; % RMSE+ = percent decrease for RMSE when satellite-derived bathymetry is aligned with external data.
Table 7.
Validation error statistics for Cocos Lagoon and Achang Reef Flat Preserve, Guam (GU). Max. = maximum; St. Dev. = standard deviation; MAE = mean absolute error; MAD = median absolute deviation; RMSE = root mean square error; % Out. = percent outliers; −Out.< = negative outliers smaller than; +Out.> = positive outliers greater than; % RMSE+ = percent decrease for RMSE when satellite-derived bathymetry is aligned with external data.
The spatial distribution of validation errors for data aligned with or calibrated to ATL24 bathymetric data for all three methods and sites together with their respective negative and positive error outliers are presented in Figure 8. We choose to show only these spatial distributions of validation errors because the alignment or calibration to ATL24 is common for all methods and sites, and the spatial pattern error distribution per method and site is similar to all other surfaces (see error distribution violin plots, Figure 5, Figure 6 and Figure 7).
Figure 8.
Spatial distribution of bathymetry validation errors for three different satellite-derived bathymetry (SDB) methods (columns) and sites ((a) Puerto Rico, (b) Florida, and (c) Guam); SDB data were aligned with or calibrated to ATL24. Red–white gradient = negative errors; white–blue gradient = positive errors; purple = negative outliers; black = positive outliers.
Validation error statistics split by water depths, 0 to −5 m and −5 m to maximum depth for all sites and methods aligned with ATL24 are available in Table 8.
Table 8.
Validation error statistics split by water depth for Cabo Rojo, Puerto Rico, Key West, Florida and Cocos Lagoon and Achang Reef Flat Preserve, Guam. Stats = statistics; m = meters; Dist = distance; Med = median; St. Dev. = standard deviation; MAE = mean absolute error; MAD = median absolute deviation; RMSE = root mean square error; No. pts = number of points present in that split water depth population.
4. Discussion
Because the band-ratio SatBathy results need some external bathymetric data for calibration to transform pseudo-depths into real bathymetric depths, a subsample of ATL24 bathymetric data was used such that for each 1-m depth interval, five random ATL24 points within that interval were used. These ATL24-calibrated data are considered equivalents of the ICP ATL24-aligned bathymetric data for the physics-based and photogrammetric methods. Despite this, the SatBathy results were further ICP-aligned with the complete set of ATL24 data to test if a further alignment would benefit the model accuracy.
The SDB depth penetration depends mainly on the site water quality when the satellite imagery was acquired and is independent of the method or satellite sensor used (Figure 5, Figure 6 and Figure 7 and Table 5, Table 6 and Table 7). Only the results from Guam seem to run counter to this hypothesis, but the majority of depths beyond −25 m have a large percentage of errors that are, in majority, outliers and are located beyond the fore reef steep slope for the physics-based and composite band-ratio methods, whereas the photogrammetric results do not extend beyond the shallower (0–25 m depth) reef flat.
Because the stereo photogrammetry method generates an integrated TBDEM surface, one can take advantage of the readily available topographic data for alignment, both lidar topography and ICESat-2 ATL06 data. The three sites’ TBDEM results have between 10 and 50% surface topography, and this provides the opportunity to test if a larger topographic area aligned with high-accuracy external topographic data increases the bathymetric accuracy.
All models error statistics for all sites (Table 5, Table 6 and Table 7) include the root mean square error (RMSE), the mean absolute error (MAE), and the median absolute deviation (MAD) error as complementary accuracy model-related metrics for data with outliers removed using the Tukey method [59]. RMSE penalizes larger errors more heavily and is very sensitive to error variance, making it useful when minimizing the spread of error is critical. MAE is less sensitive to large errors because it handles errors linearly, provides insights into potential model biases and is useful when noise, such as jitter, is present. MAD is considered a more robust measure of the variability of error dispersion and is the least influenced by outliers. A recent discussion of these three-error metrics’ usefulness in evaluating different models is present in [60], but a consensus as to which error metric is more useful to determine the reliability of a model has not been definitively reached (arguably) for the last 200 years in the statistical field. The results will be addressed by site to highlight site differences, followed by a generalized discussion across sites.
Table 8 includes error statistics split by water depths for all methods and sites. The results will be addressed in detail by site to determine if the error distribution by water depths can explain overall data bimodality. Traditionally a distribution is characterized by mean and standard deviation, but in Table 8, only the distances (absolute difference) between the two distributions’ mean and standard deviation were recorded. For all distributions considered, the number of points is large enough (from 4000 points to over 38 million points) that the usual statistical significance tests are not indicative of real distinctiveness/singularity between different distributions’ means or standard deviations split by depth.
4.1. Cabo Rojo, Puerto Rico
For Cabo Rojo, only the physics-based and composite band-ratio SatBathy methods derive a continuous bathymetric surface, whereas the stereo photogrammetry SaTSeaD has data gaps where the water was too deep, and no bottom structure was visible in the imagery (Figure 5). Despite this, all photogrammetry results, including the unaligned one, perform the best in validation metrics (MAE, MAD, and RMSE are sub-meter) despite noisier and sometimes obvious satellite jitter errors (noticeable vertical strips, Figure 8.a and Table 5). The errors in both the physics-based and composite band-ratio methods (data gap locations) are very high or outliers, indicating that despite continuous results, they are not very accurate (Figure 8).
The physics-based bathymetry results aligned with ATL24, and composite band-ratio calibrated to ATL24 and aligned with ATL24 have RMSE values above 1 m (Table 5). The composite band-ratio validation errors also exhibit some visible jitter “banding” in the southwest area (Figure 8a, third column). For all three methods, most of the positive validation errors in the southwest corner and around the western side of the Cabo Rojo peninsula (blue gradient color, Figure 8a) have similar spatial distribution, indicating that for these areas, all methods derived deeper bathymetric values, although with different ranges by method, than the bathymetric lidar measurements and correspond to relatively shallower waters. Similarly for the physics-based and composite band-ratio, most negative errors are clustered between the two main positive error areas mentioned above and south of the Cabo Rojo peninsula, extending eastwards, indicating shallower modeled bathymetry than the respective lidar data (red gradient color, Figure 8a). A less clear pattern for positive errors is present in the photogrammetric model. These patterns generate the bimodality of their error distribution (especially for the physics-based and composite band-ratio methods).
It is interesting to note that although the Puerto Rico TBDEM has very little actual topography (around 10% of total area) available for alignment with highly accurate lidar topographic data, the bathymetry accuracy increased somewhat (5.26% decrease in RMSE). On the other hand, the topographic alignment with ATL06 produces a negligible decrease in RMSE (Figure 5 and Table 5), probably due to the very restricted extent of the dataset and a lower vertical accuracy than the topographic lidar data.
The error distribution is approximately unimodal, with relatively symmetric tails for all photogrammetric models except the model aligned with topographic lidar, where the error distribution hints at a bimodal distribution, with the two modes close to each other having similar frequencies. In contrast, both physics-based and composite band-ratio models have a bimodal distribution with somewhat better-defined modes with more distinct frequencies (Figure 5, third column). This relative bimodality in error distribution is a response of the SDB model results having different error distributions for shallow depths down to −5 m versus deeper waters below −5 m (Table 8). The relative unimodality of the SaTSeaD aligned data is illustrated by the small distance between the shallow versus deeper water error distributions’ mean of 0.053 m (Table 8). For this method, the standard deviation distance is relatively larger at 0.20 m (Table 8). For the other two methods, the distance between the water depths error distributions is at least four times bigger for mean distances, and more than twice as large for standard deviation distances (Table 8).
4.2. Key West, Florida
For Key West, the SDB maximum depth penetration is slightly below 7 m. For this site, the composite band-ratio calibrated, with or without ATL24 alignment, has the best accuracy related metrics, followed closely by the physics-based method aligned with ATL24. Both methods have accuracy metrics below half a meter (0.36 and 0.32 m RMSE for the two composite band-ratio models, and 0.47 m RMSE for the physics-based model aligned with ATL24, Table 6). The photogrammetric model aligned with topographic lidar follows closely behind, with an RMSE slightly above half a meter (0.56 m). For this area, the TBDEM has approximately 25% topography (Figure 6). Despite an extensive set of ATL24 bathymetric data for this area (Figure 6), the error metrics for the photogrammetry model improve approximately the same amount irrespective of bathymetric alignment with ATL24 or topography alignment with ATL06 (RMSE decreases 38.1 and 38.8%, respectively, Table 6).
The photogrammetry and physics-based models for Key West have an obvious north–south trend/tilt slant, although the tilt is reversed between the photogrammetry and the physics-based models (Figure 8b). The same obvious tilt is not as prevalent in the composite band-ratio model. To test this observation, both the photogrammetric and the physics-based results aligned with ATL24 were detrended using the lidar TBDEM and a second-order polynomial, using xDEM Python library (version 0.1.0) [61]. Using second-order polynomials for detrending allows for a more accurate representation of the terrain without overfitting and can account for the general terrain slope and/or curvature when compared with reference data (lidar TBDEM). To measure the improvement achieved after detrending, the median and normalized mean absolute deviation (NMAD) should decrease from before to after detrended surfaces relative to the xDEM computed reference surface (Table 9).
Table 9.
Error statistics comparison between before and after detrended surfaces with second-order polynomial for Key West, Florida using xDEM. NMAD = normalized mean absolute deviation.
The SDB bathymetric data validation was performed using the same lidar data source after detrending, thus the error distribution and minimization just prove that the detrending was successful rather than ensuring a formal validation, as was performed for previous SDB datasets (Figure 9 and Table 10).
Figure 9.
Spatial distribution of bathymetry validation errors and statistics for photogrammetry (a) and physics-based (b) methods in Key West, Florida. Red–white gradient = negative errors; white–blue gradient = positive errors; purple = negative outliers; black = positive outliers; KDE = kernel density estimate. (Note: KDE is not constrained to the range [0, 1].) Black arrow indicates the tilt trend. Values for black arrow indicate the mean of negative validation errors without outliers, and the mean of positive errors without outliers for each respective method.
Table 10.
Validation error statistics for Florida detrended surfaces. St. Dev. = standard deviation; MAE = mean absolute error; MAD = median absolute deviation; RMSE = root mean square error; % Out. = percent outliers; −Out.< = negative outliers smaller than; +Out.> = positive outliers greater than; % RMSE+ = percent decrease for RMSE when SDB aligned with external data.
For both the photogrammetric and physics-based models aligned with ATL24 and detrended with second-order polynomial, the RMSE decreases over 60% from their respective original non-aligned models and ~40% for the respective model before detrending, with all three accuracy-related metrics below half a meter (Table 10). The physics-based aligned with ATL24 and detrended model slightly outperforms both the detrended photogrammetric method and the composite band-ratio model aligned with ATL24 (Table 6 and Table 10) that previously had the smallest error metrics. On the other hand, the two detrended models and the composite band-ratio model calibrated to and aligned with ATL24 have all error metrics below 0.5 m, with a difference of ~0.12 m between their respective extreme RMSE, 0.11 m between their extreme MAE, and 0.09 m between their extreme MAD values. This indicates that all three method results are comparable in their error metrics performance because the difference between the best and the worst model judged by error metrics values is well below each respective model accuracy.
Physics-based and composite band-ratio error violin plots suggest a clear bimodal error distribution in all surfaces (Figure 7 and Table 8), with well-defined and separated peaks, indicating the existence of two distinct error distributions with a small overlap. The physics-based method has a relatively small distance between distribution means (0.175, Table 8) but a large difference in standard deviations (0.669), whereas SatBathy has a very large distance between means (0.725 m, Table 8) with a moderate difference in respective standard deviation (0.374). In contrast, the photogrammetry errors have a less distinct separation of modes (Figure 7), even if Table 8 indicates a relatively pronounced separation between the two potential error distributions means (0.606 m, Table 8), but with similar standard deviations (0.093 m, Table 8). The bimodality of error distribution reflects different biases of the SDB data versus bathymetric lidar data for relatively shallower/deeper water, and therefore overall error mean and deviation do not well describe the overall error distribution, nor can they be considered the “average metric error” of an observation. A clear unimodal error distribution similar to a normal/gaussian distribution with a much smaller error mean and deviation is evident in both models’ detrended data (Figure 9, Table 8 and Table 9). In this case, their respective error metrics are diagnostic to the quality of the model they represent.
4.3. Cocos Lagoon and Achang Reef Flat Preserve, Guam
For Guam, the modeled bathymetric depth is greater for physics-based and composite band-ratio models than for photogrammetric models (−30 and −28 m versus −25 m, respectively). The water depth increases abruptly beyond the fore reef steep slope for the two models mentioned above (Figure 7), and these areas have most of the large errors and outliers (Figure 8, third row), whereas the photogrammetric model does not extend beyond the reef flat edge. This observation questions if the actual maximum depth modeled by all three methods is beyond −25 m and extends past the reef’s flat edge.
The WV-3 stereo imagery used for Guam has clouds and cloud shadows over both land and reef flat areas (Figure 7). Because the SaTSeaD ASP module does not incorporate, at this stage, an automatic routine to mask clouds or shadows, in these areas, the triangulation either failed (data voids) or generated erroneous values. Some of these errors were filtered at the modeled disparity map stage before the triangulation took place. Even with the effort to eliminate some of the disparity errors from the beginning, the photogrammetric unaligned model has a very big negative error bias (−2.85 m, Table 7) and, as a result, a large RMSE (2.91 m), despite a relatively small error dispersion (St. Dev. = 0.58 m, Table 7). This hints at the fact that any alignment (topography or bathymetry) performed for the photogrammetric model will drastically improve the error validation metrics by simply minimizing the error bias, if nothing else. The Guam TBDEM has the largest topography area present (~ 50%), and, unsurprisingly, the alignment with topographic lidar data generates the smallest RMSE among the three photogrammetric aligned models (0.585m, Table 7) and the smallest MAE and MAD metrics below 0.5 m, respectively (Table 7).
Similarly, the physics-based model used a Landsat image that had some small clouds over the Cocos Lagoon reef flat central area, whereas, theoretically, the composite Sentinel-2 image circumvented this problem by choosing the clearer pixel from the Sentinel-2 image stack. Despite this, the composite band-ratio model has error outliers (Figure 8c, third column) in the same general central Cocos Lagoon reef flat area as the data voids and clouds present in the photogrammetric and physics-based models. Regardless, the composite band-ratio model calibrated and aligned with ATL24 has the smallest error accuracy metrics (because outliers are removed), followed closely by the photogrammetry model aligned with topographic lidar after outlier removals (0.421 vs. 0.585 m RMSE, 0.266 vs. 0.375 m MAD, and 0.295 vs. 0.431 m MAE, respectively, Table 7).
For all three models, the error distribution (Figure 7, third row) hints to at least bimodality in most of the data, if not multi-modality. All distributions have long, thick tails for positive errors for the photogrammetric and composite band-ratio methods and negative errors for the physics-based models, indicating a potential additional error distribution with a low frequency and large spread, in addition to the relative bimodality of the rest of the error distributions. It is interesting to note that for Guam, the photogrammetry method has a small bias for deeper waters (0.026 m, Table 8) but larger for shallow water (0.344 m, Table 8), whereas the band-ratio composite method is the reverse (0.328 m for deep water and 0.022 m for shallow water, Table 8). All methods have a large error standard deviation difference greater than 1m between their respective shallow versus deeper water distributions (Table 8).
4.4. Cross-Site Discussion
One question to be answered is as follows: which method best models the bathymetry irrespective of the site’s physical and optical characteristics? Although this seems to be a trivial question, the answer is not that clearcut, even if we can perform a simple ranking of error metrics related to model accuracy and model performance per site, because the values of errors metrics across sites vary widely for error distributions far from unimodal or normal. In addition, each error metric considered highlights different responses between metrics highly influenced by large errors and bias (RMSE) to relatively robust measures to extreme errors such as MAD and MAE. This forces one to consider what is more important when modeling underwater morphology: the minimization of extreme errors and what might generate them, or the behavior of most of the data? To address this, mean-weighted, mean-ranking indexes for the aligned or calibrated surfaces (because they have usually smaller error metrics than the unaligned counterparts) were calculated for all three methods and sites (nine for photogrammetry, three for physics-based, and six for composite band-ratio) as follows:
where
- m = number of different error metrics to consider;
- n = number of different surfaces for individual SDB models;
- = method error metrics rank per site—integer values between 1 and maximum numbers of methods considered.
An example calculation for composite band-ratio method for Guam (Table 7) is presented here. There are two surfaces, one calibrated to ATL24 and one calibrated to and aligned with ATL24. According to the rule above, the rank for all three error metrics (MAE, MAD, and RMSE) is 1 (smallest error values among all three methods for Guam). All error metrics values are below 0.5 m, except the RMSE for the calibrated surface only (0.519 m, Table 7). That means the metric mean error weight is 0.50 for MAE and MAD and 0.75 for RMSE. The overall weighted rank index value for composite band-ratio for Guam is as follows:
If the weighted rank index for the composite band-ratio is similarly calculated for Puerto Rico (Table 5), the weighted rank index value is 2.00, and for Florida (Table 6), it is 0.50. The overall weighted ranking index for all sites and methods following the above logic is presented in Table 11.
Table 11.
Weighted ranking index per method.
Besides the final weighted ranking index, the photogrammetry method is considered the most consistent across all three sites (Table 11). However, the photogrammetry SaTSeaD Florida results are heavily penalized due to simple ranking, with the difference between the first-ranked RMSE (0.319 m for composite band-ratio method calibrated to and aligned with ATL24) and the third-ranked RMSE (0.564 m, photogrammetry aligned with lidar topography) being only ~0.24 m and within each method’s error margins. Further, if the detrended results for Florida (Table 10 and Figure 8) are considered, the ranking will flip between the best composite band-ratio and physics-based aligned data, and even if the photogrammetric detrended data keep the same third ranking, the new range difference between extreme RMSEs decreases further to ~0.12 m, with all methods error metrics below 0.50 m, decreasing the metrics mean weights from 1.0 to 0.5. Furthermore, it is hard to adequately discern the real accuracy of the physics-based method, because it uses the same global generic bottom spectral data for all three sites, and from the error validation results (Table 5, Table 6 and Table 7) and weighted ranking index per site (Table 11), it seems that this library is more suited to sandy bottom with very low percentage of stony reefs, such as for Florida bottom classification, than for steep, rough, stony coral-covered seafloor more common for Puerto Rico and Guam bottom classifications. This indicates that with a better site-specific bottom spectral look-up table, the physics-based results will have an increase in accuracy, probably similar to the photogrammetric and composite band-ratio methods that are more sensitive to the site-specific conditions.
Judging strictly by the different error metrics values (minimal MAE, MAD, and RMSE), the composite band-ratio method has better results in two out of three sites, the photogrammetry method has better results in one out of three sites, and the physics-based method is second in one out of three sites. But the SDB error metrics values related to model accuracy are not sufficient to decide which model follows closest to the real bottom morphology, especially if that error distribution is bimodal. It is worth mentioning that the SDB error distribution bimodality is independent of maximum bathymetry depth resolved by the method because this bimodality is present in both Florida, with a maximum depth of 7 m, and Puerto Rico and Guam, where the maximum depth is 25 m or greater. For SDB models with comparable error statistics, the error distribution might be the deciding factor, although more research is needed to exhaustively answer this question. Because SDB error distribution tends to be bimodal irrespective of method, alignment, site, or maximum depth (with the debatable exception of the photogrammetry method for PR), performing detrending, when possible, results in an error distribution close to normal, and thus the error metrics can be interpreted as average errors of observations.
The composite band-ratio method is closely followed in performance by the aligned photogrammetry method, even though, at least for Florida, it presents a clear north–south trend or tilt in the data (Figure 8b). The same direction, but with an opposite tilt slant, is present in the Florida physics-based SDB results as well. If detrending is possible, both the photogrammetry and physics-based methods’ results are very similar to the composite band-ratio result, and their error distributions are close to normal. Without detrending, only the composite band-ratio method has an overall RMSE less than 5% of the total bathymetry depth for Florida, but after detrending, the physics-based method has a smaller RMSE than the composite band-ratio method.
Everything becomes more complicated if one considers model error distributions, which with few exceptions (arguably the photogrammetric models for Puerto Rico and the detrended models for Florida) have a bimodal distribution. Because models with a bimodal error distribution imply different error distributions (e.g., different SDB error biases for shallower versus deeper waters with different standard deviations, Table 8), then maybe the deciding factor should not be exclusively the error metrics values, but also the error distribution. For a unimodal distribution approaching normality, the error mean and standard deviation are representative of the distribution, and their respective error statistics related to the model accuracy are more indicative of model truthfulness. In this case, it would mean that the model with the least bimodal “degree” has a better chance to have more diagnostic error metrics to assess the quality of the model. The error distribution bimodality could also be related to the way the final SDB surface is generated, at least for the photogrammetry and composite band-ratio methods that handle very shallow water differently than the deeper one, whereas the physics-based method might be more dependent on accurate information for bottom type. Nevertheless, all methods, including physics-based, display bimodality to some degree in their error distribution if not detrended. Computing the bimodality of an error distribution and deciding which metric is better in this endeavor constitutes a large domain in statistics, and it is beyond the scope of this paper. Nevertheless, one might be interested in the degree of the bimodality error distribution if it is considered that the bimodality reflects the underlaying heterogeneity, such as divergence, or the result of two different distributions combined into one. The latter case may indicate, for example, that SDB has distinct biases and spread around the mean (standard deviations) for shallow versus deeper water when compared with lidar bathymetric measurements [41].
The processing time between the three SDB methods for the same area varies between approximately one hour for PBSDB and SatBathy to approximately 8 h or more for photogrammetry for an area of approximately 20 × 10 km. In addition, these methods use different satellite resolution data, and for the same area, Sentinel-2 has nine times more pixels (10-m resolution), and WorldView has 225 more multispectral pixels (2-m resolution) and 3600 more PAN pixels (0.5-m resolution) than Landsat imagery (30-m resolution). The general user-friendliness of the three methods is different as well, with the photogrammetry method requiring a steeper learning curve despite a very detailed published user’s manual [62] for its open-source software [63], whereas SatBathy may be relatively easier to use when its public release will be available to process imagery in the cloud.
Whereas physics-based and band-ratio composite methods will generally produce a continuous bathymetric surface, the stereo photogrammetry-derived bathymetric surface can have data gaps due to lack of bottom texture or water depth. Despite this, stereo photogrammetry is the single method capable of generating a seamless topo-bathymetric DEM for coastal areas. The band-ratio composite method has the advantage of being able to somewhat circumvent some of the water-turbidity problems or eliminate cloud interference. Landsat SDB methods have the advantage of a wide timeframe of data availability (since 1985) that facilitate opportunities for bathymetric change analysis.
5. Conclusions
The maximum depth penetration for SDB depends primarily on the site water clarity and characteristics, and not the different basic SDB methods used (photogrammetric, physics-based, or band-ratio) or different satellite optical sensors (WorldView 2 and 3, Landsat 8 and 9, and Sentinel-2).
Our analysis demonstrates that, generally, all SDB methods’ accuracy will increase when calibrated or aligned with external bathymetric data, as long as the data have higher accuracy than the original SDB data. With the advent of the ICESat-2 ATL24 global bathymetry track data, which have been freely available since April 2025, with an acceptable vertical accuracy of less than 0.5 m [28], those data are a source for improving other SDB methods. This widely opens the era of pure space-borne SDB modeling that contributes to regional integrated bathymetry in challenging shallow coastal environments worldwide.
Only the photogrammetry method can generate a continuous TBDEM that opens the possibility to align the TBDEM results with external high-accuracy topographic data, such as lidar, to improve bathymetric accuracy. The bathymetric accuracy increases with the increase in percent topography available for alignment, as evidenced by the error metrics reduction for all three sites presented here between alignment with ATL06 track data versus available high-accuracy topographic lidar data, or between unaligned and topographically aligned data (Table 5, Table 6 and Table 7).
It is obvious that the satellite optical instrument influences the SDB resolution, but not necessarily the bathymetric accuracy or the maximum bathymetric depths resolved. For the three sites, only the photogrammetric results and, to some extent, the composite band-ratio results display jitter errors that are related to the satellite instrument. Conversely, the SDB method itself seems to weakly influence the overall SDB accuracy per site, especially because now ICESat-2 ATL24 track bathymetry data are freely available, opening all SDB methods to a pure space-borne solution. Overall, the site’s physical characteristics, such as water quality and property, bottom classification and structure, and maybe even the underwater surface geology, are the major factors that influence SDB accuracy rather than any other considerations.
As major points, SDB error distributions can be bimodal irrespective of method, satellite instrument, maximum bathymetric depth resolved, or site, and consequently, the error metrics are not symptomatic for these distributions. The bimodality is a response to the SDB data having different biases (often regarding opposing signs) for relatively shallow versus deeper waters that are not adjusted by the alignment with ATL24 bathymetric track data. When adequate data are available, detrending can transform the SDB bimodal error distribution to a unimodal distribution close to normal and seems to decrease the error spread and, consequently, all the other error metrics. If detrending is not feasible, then researchers and users of SDB data should be aware of the bimodality tendency and the fact that the error metrics might not be as diagnostic for the model as when the error distribution approaches normality or is at least unimodal. This consideration has implications for change analysis using different SDB surfaces because bimodality does not guarantee the same sign bias in all SDB surfaces for very shallow or deeper waters for the same site.
Ultimately, the selection of SDB method and satellite sensor rests with the researcher, the minimum resolution needs (2–5 m, 10 m, 30 m) to answer a specific question, satellite-imagery availability (free for medium-resolution; commercial for high-resolution), and even the access to processing software (published open-source, licensed, in-house code).
Author Contributions
Conceptualization, M.P.-L. and J.D.; methodology, M.P.-L., M.K. and B.E.; validation, M.P.-L. and J.D.; formal analysis, M.P.-L.; investigation, M.P.-L.; resources, J.D., G. I. and C.S.; writing—original draft preparation, M.P.-L.; writing—review and editing M.P.-L., B.E., M.K., G.I. and C.S.; visualization, M.P.-L., B.E. and M.K.; supervision, M.P.-L., J.D. and G.I.; project administration, M.P.-L., J.D. and G.I.; funding acquisition, J.D. and C.S. All authors have read and agreed to the published version of the manuscript.
Funding
This research was funded by the Office of Naval Research (ONR) through interagency agreement N0001422IP00049 and the U.S. Geological Survey (USGS), Coastal and Marine Hazards and Resources Program (CMHRP).
Data Availability Statement
WorldView commercial satellite data for licensed users are available at https://earthexplorer.usgs.gov/ (accessed on 9 September 2025). Landsat data are freely available from the U.S. Geological Survey Earth Explorer at https://earthexplorer.usgs.gov/ (accessed on 9 September 2025). Sentinel-2 data are freely available from the Registry of Open Data on AWS (2025) at https://registry.opendata.aws/sentinel-2/(accessed on 9 September 2025). The 2019 NOAA NGS Topobathy Lidar: Puerto Rico, available at https://www.fisheries.noaa.gov/inport/item/65546 (accessed on 9 September 2025); The 2018 USACE FEMA Topobathy Lidar: Main Island, Culebra, and Vieques, Puerto Rico. NOAA National Centers for Environmental Information, available at https://www.fisheries.noaa.gov/inport/item/53078. (accessed on 9 September 2025) The 2018–2019 NOAA NGS Topobathy Lidar Hurricane Irma: Miami to Marquesas Keys, FL, available at https://www.fisheries.noaa.gov/inport/item/63017 (accessed on 9 September 2025). The 2020 NOAA NGS Topobathy Lidar: Guam, available at https://www.fisheries.noaa.gov/inport/item/64811 (accessed on 9 September 2025). Any use of trade, firm, or product names is for descriptive purposes only and does not imply endorsement by the U.S. Government.
Acknowledgments
The authors would like to thank Christopher Parrish, at the School of Civil and Construction Engineering, Oregon State University; and Ashton Wiens, U.S., Geological Survey Geology, Energy and Minerals Science Center, for their wonderful first reviews that improved and expanded this manuscript. The authors are equally grateful to the anonymous journal reviewers whose comments improved this article.
Conflicts of Interest
The authors declare no conflicts of interest. The funders had no role in the design of the study; in the collection, analyses, or interpretation of data; in the writing of the manuscript; or in the decision to publish the results.
References
- Ashphaq, M.; Srivastava, P.K.; Mitra, D. Review of Near-Shore Satellite Derived Bathymetry: Classification and Account of Five Decades of Coastal Bathymetry Research. J. Ocean Eng. Sci. 2021, 6, 340–359. [Google Scholar] [CrossRef] [Scilit]
- Lyzenga, D.R. Passive remote sensing techniques for mapping water depth and bottom features. Appl. Opt. 1978, 17, 379–383. [Google Scholar] [CrossRef] [Scilit]
- Landsat Archive Became Freely Available in 2008. USGS News. Available online: https://www.usgs.gov/media/files/2008-free-landsat-image-archive-news-release (accessed on 9 September 2025).
- Sentinel-2A. European Space Agency. Available online: https://www.esa.int/Applications/Observing_the_Earth/Copernicus/Sentinel-2/Sentinel-2_delivers_first_images (accessed on 9 September 2025).
- Neumann, T.A.; Martino, A.J.; Markus, T.; Bae, S.; Bock, M.R.; Brenner, A.C.; Brunt, K.M.; Cavanaugh, J.; Fernandes, S.T.; Hancock, D.W.; et al. The Ice, Cloud, and Land Elevation Satellite-2 Mission: A Global Geolocated Photon Product Derived from the Advanced Topographic Laser Altimeter System. Remote Sens. Environ. 2019, 233, 111325. [Google Scholar] [CrossRef] [Scilit]
- Bell, J.D.; Albert, J.; Andréfouët, S.; Andrew, N.L.; Blanc, M.; Bright, P.; Brogan, D.; Campbell, B.; Govan, H.; Hampton, J.; et al. Optimising the Use of Nearshore Fish Aggregating Devices for Food Security in the Pacific Islands. Mar. Policy 2015, 56, 98–105. [Google Scholar] [CrossRef] [Scilit]
- Dunn, D.C.; Stewart, K.; Bjorkland, R.H.; Haughton, M.; Singh-Renton, S.; Lewison, R.; Thorne, L.; Halpin, P.N. A Regional Analysis of Coastal and Domestic Fishing Effort in the Wider Caribbean. Fish. Res. 2010, 102, 60–68. [Google Scholar] [CrossRef] [Scilit]
- Flower, J.; Ramdeen, R.; Estep, A.; Thomas, L.R.; Francis, S.; Goldberg, G.; Johnson, A.E.; McClintock, W.; Mendes, S.R.; Mengerink, K.; et al. Marine Spatial Planning on the Caribbean Island of Montserrat: Lessons for Data-limited Small Islands. Conserv. Sci. Pract. 2020, 2, e158. [Google Scholar] [CrossRef] [Scilit]
- Foley, M.M.; Halpern, B.S.; Micheli, F.; Armsby, M.H.; Caldwell, M.R.; Crain, C.M.; Prahler, E.; Rohr, N.; Sivas, D.; Beck, M.W.; et al. Guiding Ecological Principles for Marine Spatial Planning. Mar. Policy 2010, 34, 955–966. [Google Scholar] [CrossRef] [Scilit]
- Parodi, M.U.; Giardino, A.; van Dongeren, A.; Pearson, S.G.; Bricker, J.D.; Reniers, A.J.H.M. Uncertainties in Coastal Flood Risk Assessments in Small Island Developing States. Nat. Hazards Earth Syst. Sci. 2020, 20, 2397–2414. [Google Scholar] [CrossRef] [Scilit]
- Guidance on Use of Satellite to Gather Depth Data. International Hydrographic Organization (IHO). 2024. Available online: https://iho.int/en/guidance-on-use-of-satellites-to-gather-depth-data (accessed on 9 September 2025).
- Volckmann, R.P. Geologic map of the Cabo Rojo and Parguera quadrangles, southwest Puerto Rico; USGS IMAP 1557; U.S. Geological Survey: Reston, VA, USA, 1984. [CrossRef] [Scilit]
- Prada, M.C.; Appeldoorn, R.S.; Rivera, J.A. Improving Coral Reef Habitat Mapping of the Puerto Rico Insular Shelf Using Side Scan Sonar. Mar. Geod. 2008, 31, 49–73. [Google Scholar] [CrossRef] [Scilit]
- Schlee, J.S.; Rodriguez, R.W.; Webb, R.M.; Carlo, M.A. Marine geologic map of the southwestern insular shelf of Puerto Rico, Mayaguez to Cabo Rojo; USGS IMAP 2615; U.S. Geological Survey: Reston, VA, USA, 1999. [CrossRef] [Scilit]
- Halley, R.B.; Vacher, H.L.; Shinn, E.A. Geology and Hydrogeology of the Florida Keys. In Developments in Sedimentology; Elsevier: Amsterdam, The Netherlands, 2004; pp. 217–248. [Google Scholar] [CrossRef] [Scilit]
- Siegrist, H.G., Jr.; Reagan, M.K. Generalized Geology of Guam, Mariana Islands: Field interpretations assisted by Richard H. Randall and John W. Jenson. 2008. Available online: https://www.weriguam.org/pdf/general-geology-and-stratigraphy-of-guam-map.pdf (accessed on 9 September 2025).
- Tracey, J.I., Jr.; Schlanger, S.O.; Stark, J.T.; Doan, D.B.; May, H.G. Geology and Hydrology of Guam, Mariana Islands: A Study of the Stratigraphy, Structure, and Tertiary Geologic History of the Southern Most Island of the Mariana Arc; Geological Survey Professional Paper 403-A: Guam, Northern Mariana Islands, 1964. Available online: https://pubs.usgs.gov/pp/0403a/report.pdf (accessed on 9 September 2025).
- Myers, R.F.; Donaldson, T.J. The fishes of the Mariana Islands. Micronesica 2003, 35, 594–648. [Google Scholar]
- van Beukering, P.; Haider, W.; Longland, M.; Cesar, H.; Sablan, J.; Shjegstad, S.; Beardmore, B.; Liu, Y.; Garces, G.O. The economic value of Guam’s coral reefs. Univ. Guam Mar. Lab. Tech. Rep. 2007, 116, 102. [Google Scholar]
- WorldView-2 Data Sheet. Maxar. 2009. Available online: https://vantor.com/resources/worldview-2-datasheet/ (accessed on 9 September 2025).
- WorldView-3 Data Sheet. Maxar. 2014. Available online: https://vantor.com/resources/worldview-3-datasheet/ (accessed on 9 September 2025).
- Earth Explorer. U.S. Geological Survey. Available online: https://earthexplorer.usgs.gov/ (accessed on 9 September 2025).
- GloVis. U.S. Geological Survey. Available online: https://glovis.usgs.gov/ (accessed on 9 September 2025).
- U.S. Geological Survey. Landsat 9. Fact Sheet; US Geological Survey: Reston, VA, USA, 2019. [CrossRef] [Scilit]
- U.S. Geological Survey. Landsat 8 (L8) Data Users Handbook. 2019b. (LSDS-1574, ver.5, CR 15147). Available online: https://d9-wret.s3.us-west-2.amazonaws.com/assets/palladium/production/s3fs-public/atoms/files/LSDS-1574_L8_Data_Users_Handbook-v5.0.pdf (accessed on 9 September 2025).
- European Space Agency. Sentinel-2 User Handbook (Issue1, Rev. 2). 2015. Available online: https://sentinels.copernicus.eu/documents/247904/685211/Sentinel-2_User_Handbook (accessed on 9 September 2025).
- Jung, J.; Parrish, C.E.; Magruder, L.A.; Herrmann, J.; Yoo, S.; Perry, J.S. ICESat-2 Bathymetry Algorithms: A Review of the Current State-of-the-Art and Future Outlook. ISPRS J. Photogramm. Remote Sens. 2025, 223, 413–439. [Google Scholar] [CrossRef] [Scilit]
- Parrish, C.E.; Magruder, L.A.; Perry, J.; Holwill, M.; Swinski, J.P.; Kief, K. Analysis and Accuracy Assessment of a New Global Nearshore ICESat-2 Bathymetric Data Product. Earth Space Sci. 2025, 12, e2025EA004391. [Google Scholar] [CrossRef] [Scilit]
- Jasinski, M.; Stoll, J.; Hancock, D.; Robbins, J.; Nattala, J.; Morrison, J.; Jones, B.; Ondrusek, M.; Pavelsky, T.; Parrish, C. Ice, Cloud, and Land Elevation Satellite (ICESat-2) Project Algorithm Theoretical Basis Document (ATBD) for along Track Inland Water Data, Version 7. NASA Natl. Snow Ice Data Cent. Distrib. Act. Arch. Cent. 2025. [Google Scholar] [CrossRef]
- Magruder, L.A.; Parrish, C.E.; Perry, J.; Swinski, J.P.; Holwill, M.; Kief, K.; Corcoran, F. ATLAS/ICESat-2 L3A Along Track Coastal and Nearshore Bathymetry (ATL24, Version 1). Boulder, Colorado USA. NASA Natl. Snow Ice Data Cent. Distrib. Act. Arch. Cent. 2025. [Google Scholar] [CrossRef]
- Shean, D.; Swinski, J.P.; Smith, B.; Sutterley, T.; Henderson, S.; Ugarte, C.; Lidwa, E.; Neumann, T. SlideRule: Enabling Rapid, Scalable, Open Science for the NASA ICESat-2 Mission and Beyond. J. Open Source Softw. 2023, 8, 4982. [Google Scholar] [CrossRef] [Scilit]
- OCM Partners. 2018 USACE FEMA Topobathy Lidar: Main Island, Culebra, and Vieques, Puerto Rico. NOAA National Centers for Environmental Information. 2025. Available online: https://www.fisheries.noaa.gov/inport/item/53078 (accessed on 9 September 2025).
- NOAA National Geodetic Survey. 2019 NOAA NGS Topobathy Lidar: Puerto Rico. 2025. Available online: https://www.fisheries.noaa.gov/inport/item/65546 (accessed on 9 September 2025).
- ASPRS Positional Accuracy Standards for Digital Geospatial Data. Photogramm. Eng. Remote Sensing 2015, 81, 1–26. [CrossRef] [Scilit]
- NOAA National Geodetic Survey. 2018-2019 NOAA NGS Topobathy Lidar Hurricane Irma: Miami to Marquesas Keys, FL. 2025. Available online: https://www.fisheries.noaa.gov/inport/item/63017 (accessed on 9 September 2025).
- NV5 Geospatial. NOAA Hurricane Irma, Florida Keys Supplemental LiDAR & Shoreline Mapping Technical Data Report. 2020. Available online: https://noaa-nos-coastal-lidar-pds.s3.amazonaws.com/laz/geoid18/9081/supplemental/NOAA_Supplemental_Irma_Topobathymetric_LiDAR_and_Shoreline_Mapping_Report.pdf (accessed on 9 September 2025).
- The Interagency Working Group on Ocean; Coastal Mapping. National Coastal Mapping Strategy 1.0: Coastal LIDAR Elevation for a 3D Nation; NOAA: Silver Spring, Maryland, 2018. Available online: https://iocm.noaa.gov/about/documents/strategic-plans/IWG-OCM-Final-Coastal-Mapping-Strategy-2018-with-cover.pdf (accessed on 9 September 2025).
- NOAA National Geodetic Survey (NGS). 2020 NOAA NGS Topobathy Lidar: Guam. 2025. Available online: https://www.fisheries.noaa.gov/inport/item/64811 (accessed on 9 September 2025).
- NV5 Geospatial. NOAA Typhoon Yutu Supplemental Mapping, Guam and CNMI: Supplemental Lidar & Shoreline Mapping Technical Data Report. 2021. Available online: https://noaa-nos-coastal-lidar-pds.s3.amazonaws.com/laz/geoid12b/9322/supplemental/NOAA_Typhoon_Yutu_Topobathymetric_Lidar_Data_Report.pdf (accessed on 9 September 2025).
- Kim, M.; Danielson, J.; Storlazzi, C.; Park, S. Physics-Based Satellite-Derived Bathymetry (SDB) Using Landsat OLI Images. Remote Sens. 2024, 16, 843. [Google Scholar] [CrossRef] [Scilit]
- Palaseanu-Lovejoy, M.; Alexandrov, O.; Danielson, J.; Storlazzi, C. SaTSeaD: Satellite Triangulated Sea Depth Open-Source Bathymetry Module for NASA Ames Stereo Pipeline. Remote Sens. 2023, 15, 3950. [Google Scholar] [CrossRef] [Scilit]
- National Oceanic and Atmospheric Administration (NOAA). Nautical Chart User’s Manual, 3rd ed.; NOAA: Lulu Press Inc.: Silver Spring, Maryland, 2020; Volume 1.
- Sentinel-2. Opendata AWS. Available online: https://registry.opendata.aws/sentinel-2/ (accessed on 9 September 2025).
- Vanhellemont, Q.; Ruddick, K. Advantages of High Quality SWIR Bands for Ocean Colour Processing: Examples from Landsat-8. Remote Sens. Environ. 2015, 161, 89–106. [Google Scholar] [CrossRef] [Scilit]
- Wang, M.; Shi, W. Cloud Masking for Ocean Color Data Processing in the Coastal Regions. IEEE Trans. Geosci. Remote Sens. 2006, 44, 3196–3205. [Google Scholar] [CrossRef] [Scilit]
- Caballero, I.; Stumpf, R. Towards Routine Mapping of Shallow Bathymetry in Environments with Variable Turbidity: Con-tribution of Sentinel-2A/B Satellites Mission. Remote Sens. 2020, 12, 451. [Google Scholar] [CrossRef] [Scilit]
- Caballero, I.; Stumpf, R.P. Confronting Turbidity, the Major Challenge for Satellite-Derived Coastal Bathymetry. Sci. Total Environ. 2023, 870, 161898. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- NOAA/NOS Vertical Datums Transformation. (VDATUM v4.7.1). NOAA. Available online: https://vdatum.noaa.gov/ (accessed on 9 September 2025).
- Bhushan, S.; Shean, D.; Alexandrov, O.; Henderson, S. Automated Digital Elevation Model (DEM) Generation from Very-High-Resolution Planet SkySat Triplet Stereo and Video Imagery. ISPRS J. Photogramm. Remote Sens. 2021, 173, 151–165. [Google Scholar] [CrossRef] [Scilit]
- NASA Ames Stereo Pipeline User Manual Section 8.25. SkySat Stereo and Video Data. Available online: https://stereopipeline.readthedocs.io/en/latest/examples/skysat.html (accessed on 9 September 2025).
- NASA Ames Stereo Pipeline User Manual Section 8.23. Pleiades. Available online: https://stereopipeline.readthedocs.io/en/latest/examples/pleiades.html (accessed on 9 September 2025).
- Laura, J.R.; Mapel, J.; Hare, T. Planetary Sensor Models Interoperability Using the Community Sensor Model Specification. Earth Space Sci. 2020, 7, e2019EA000713. [Google Scholar] [CrossRef] [Scilit]
- NASA Ames Stereo Pipeline User Manual Section 8.30. Umbra SAR. Available online: https://stereopipeline.readthedocs.io/en/latest/examples/umbra_sar.html (accessed on 9 September 2025).
- NASA Ames Stereo Pipeline User Manual Section 8.22. PeruSat-1. Available online: https://stereopipeline.readthedocs.io/en/latest/examples/perusat1.html (accessed on 9 September 2025).
- Pomerleau, F.; Colas, F.; Siegwart, R.; Magnenat, S. Comparing ICP Variants on Real-World Data Sets: Open-Source Library and Experimental Protocol. Auton. Robots 2013, 34, 133–148. [Google Scholar] [CrossRef] [Scilit]
- Nuth, C.; Kääb, A. Co-Registration and Bias Corrections of Satellite Elevation Data Sets for Quantifying Glacier Thickness Change. Cryosphere 2011, 5, 271–290. [Google Scholar] [CrossRef] [Scilit]
- Benjemaa, R.; Schmitt, F. Fast Global Registration of 3D Sampled Surfaces Using a Multi-z-Buffer Technique. Image Vis. Comput. 1999, 17, 113–123. [Google Scholar] [CrossRef] [Scilit]
- NASA Ames Stereo Pipeline User Manual Section 16.54. pc_align. Available online: https://stereopipeline.readthedocs.io/en/latest/tools/pc_align.html (accessed on 9 September 2025).
- Tukey, J.W. Exploratory Data Analysis; Pearson: Upper Saddle River, NJ, USA, 1977. [Google Scholar]
- Hodson, T.O. Root-Mean-Square Error (RMSE) or Mean Absolute Error (MAE): When to Use Them or Not. Geosci. Model Dev. 2022, 15, 5481–5487. [Google Scholar] [CrossRef] [Scilit]
- xDEM contributors. xDEM: Robust analysis of DEMs in Python (v0.1.0). 2024. Available online: https://zenodo.org/records/11492983 (accessed on 9 September 2025).
- NASA Ames Stereo Pipeline User Manual Section 8.29. Shallow-Water Bathymetry. Available online: https://stereopipeline.readthedocs.io/en/latest/examples/bathy.html (accessed on 23 September 2025).
- NASA Ames Stereo Pipeline, Daily Software Release. Available online: https://github.com/NeoGeographyToolkit/StereoPipeline/releases (accessed on 23 September 2025).
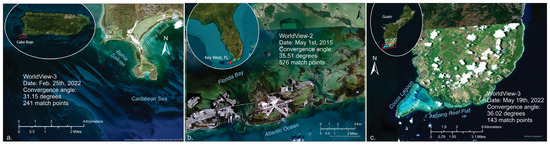
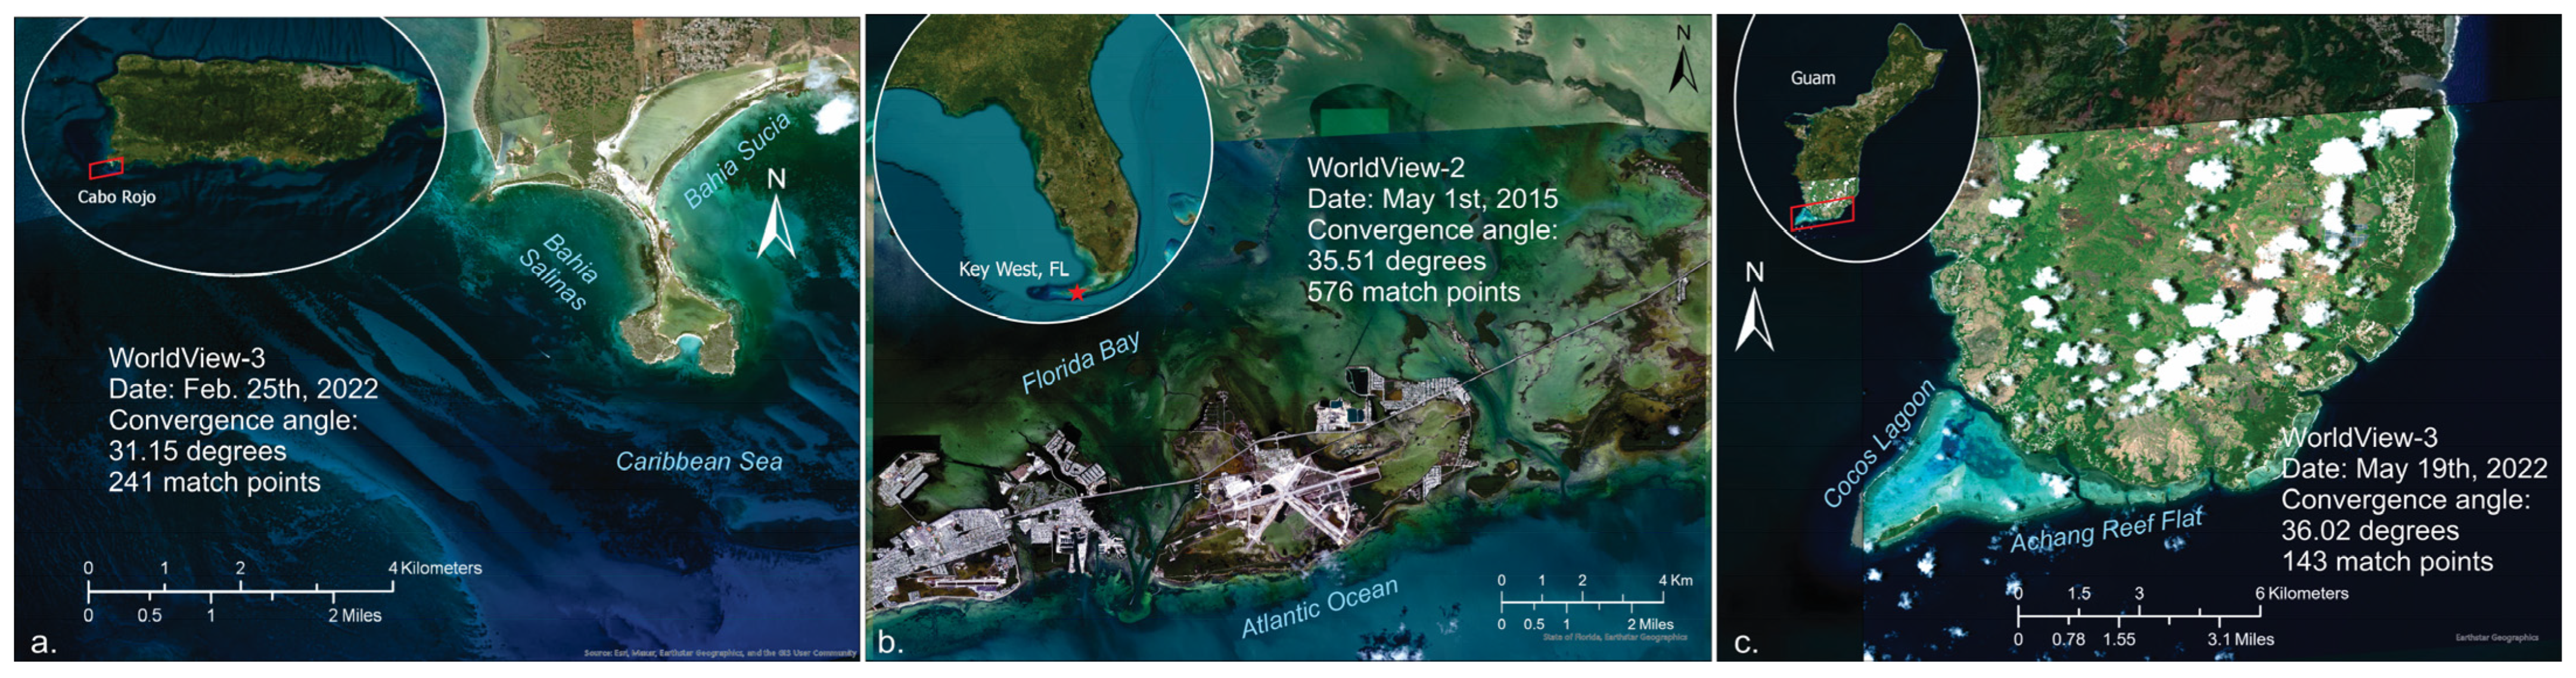
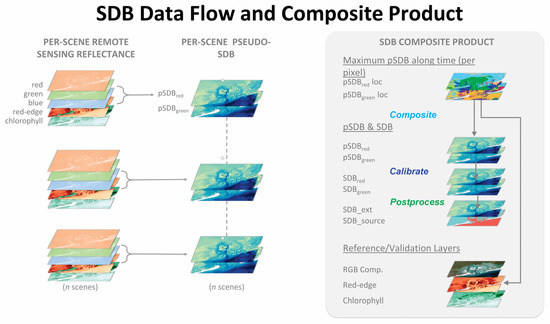
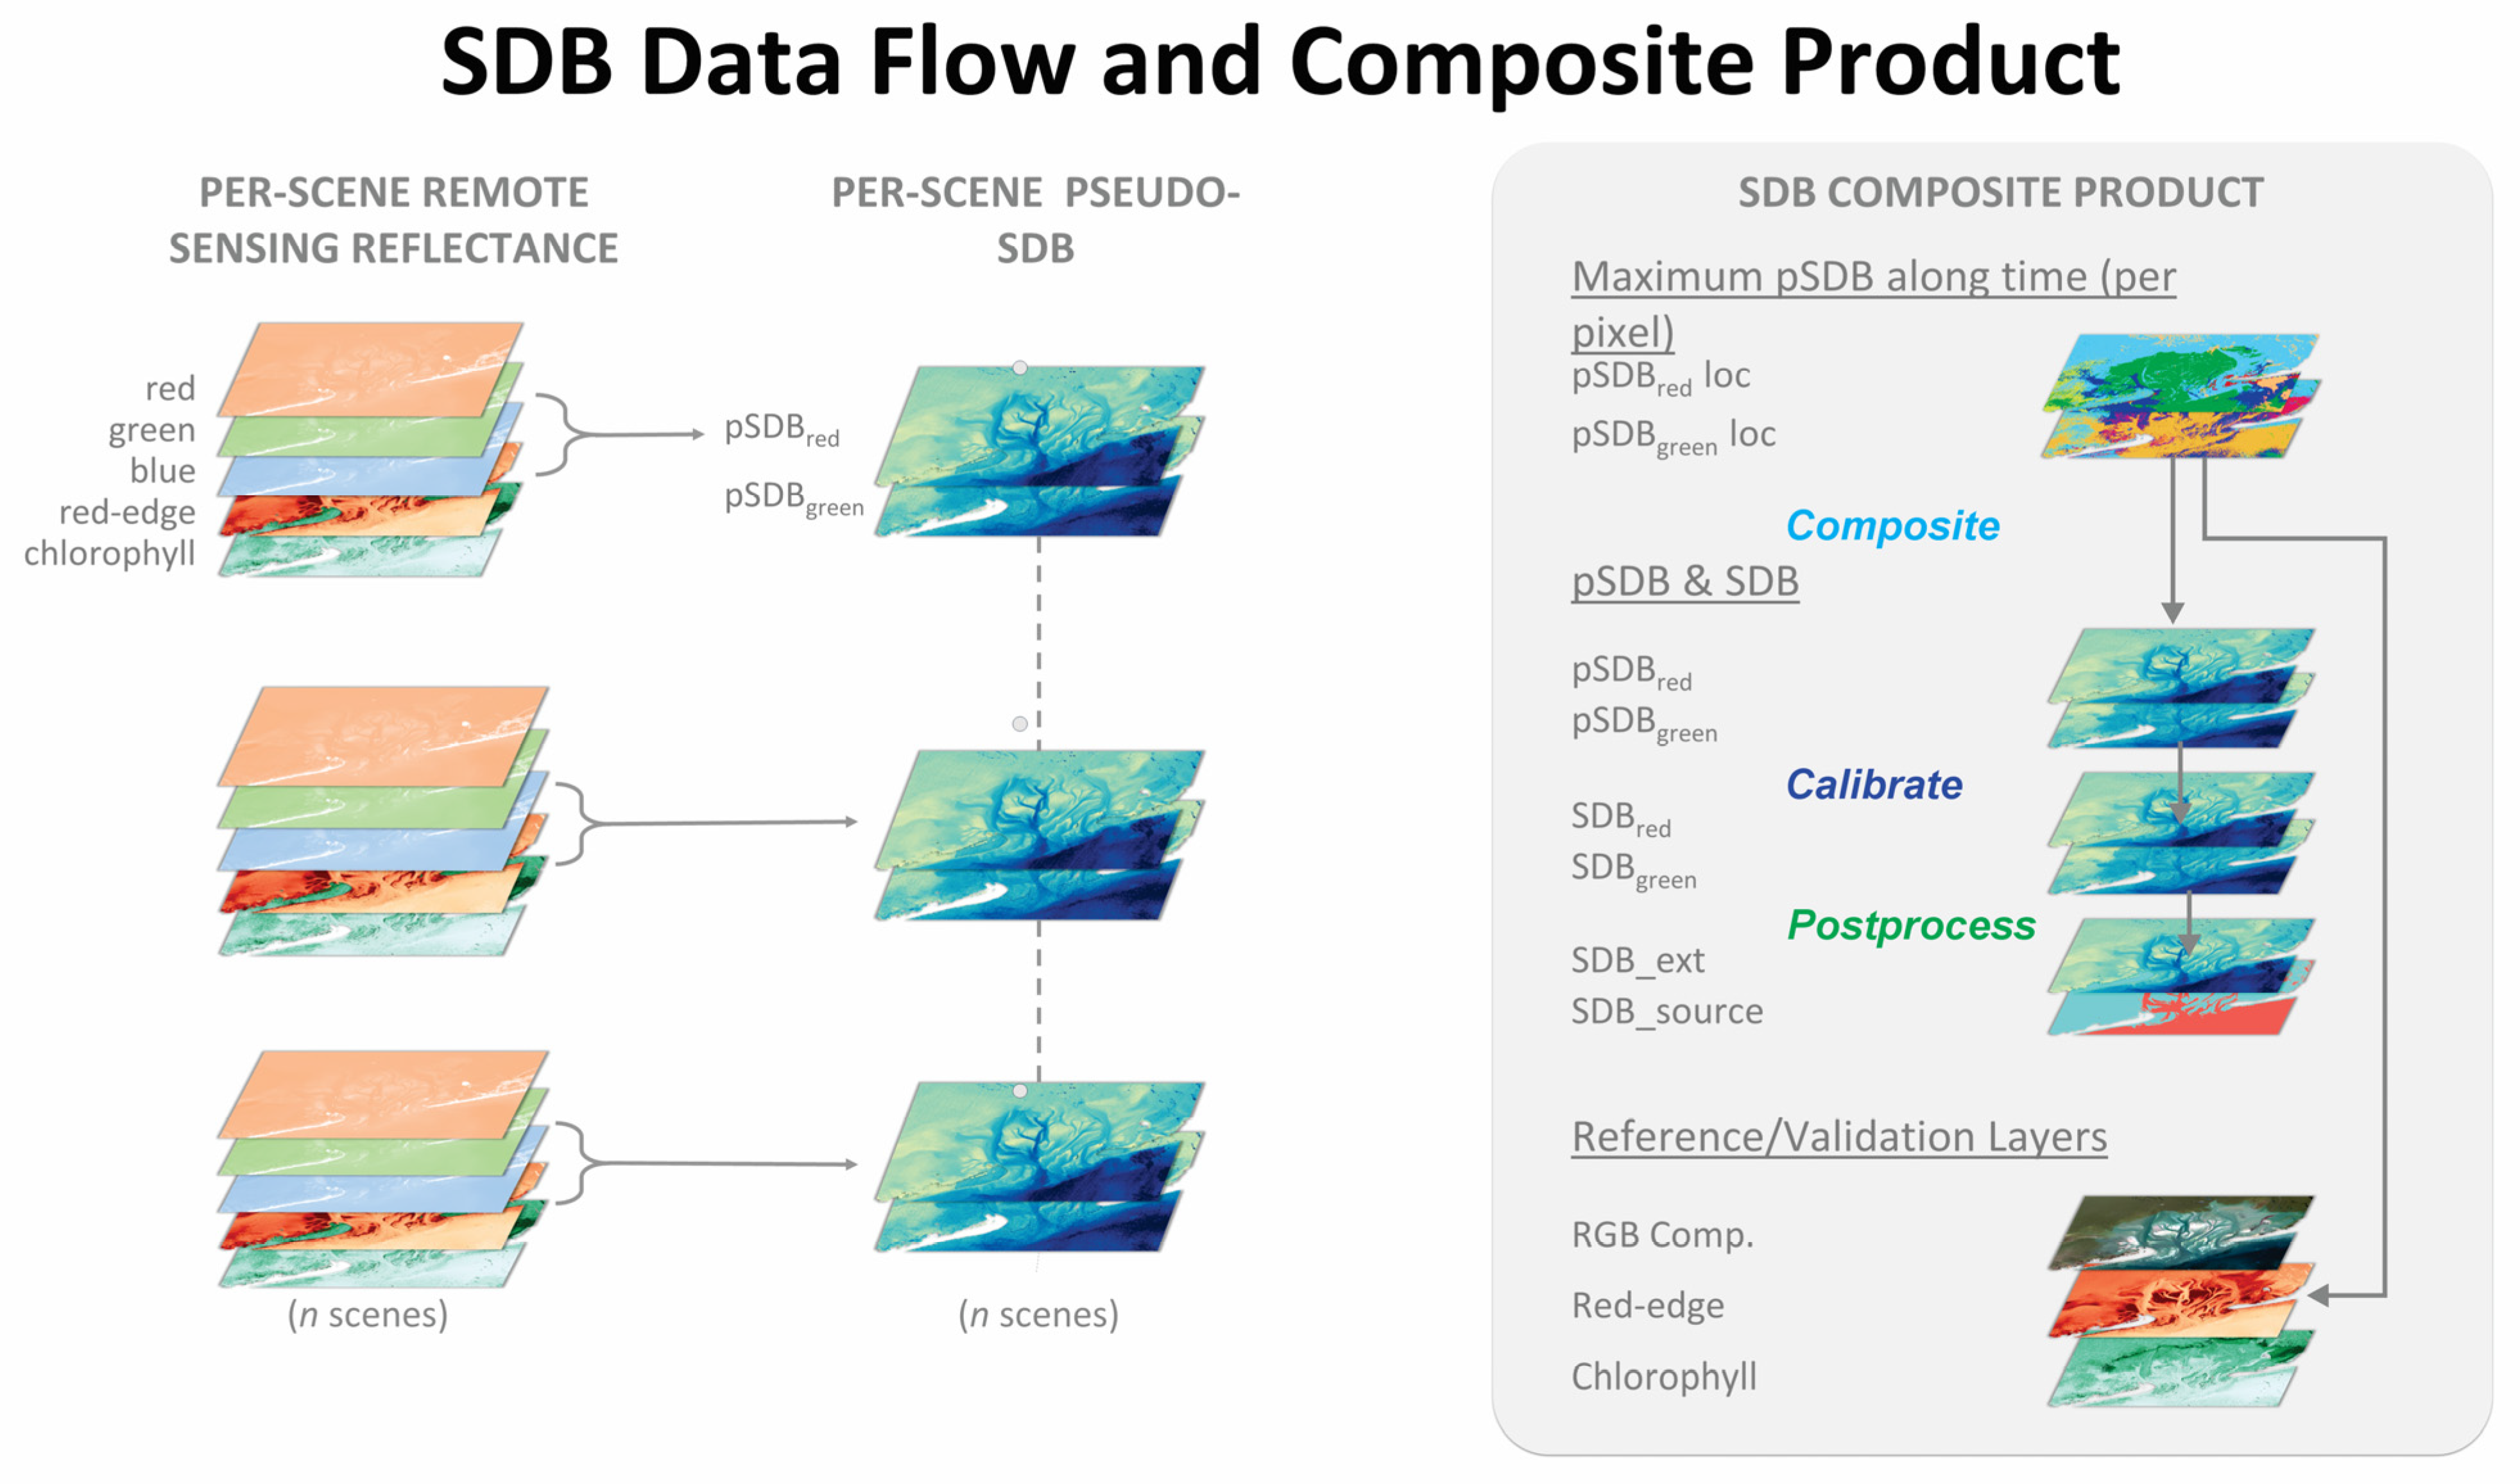
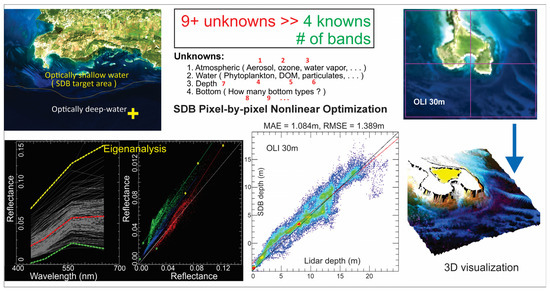
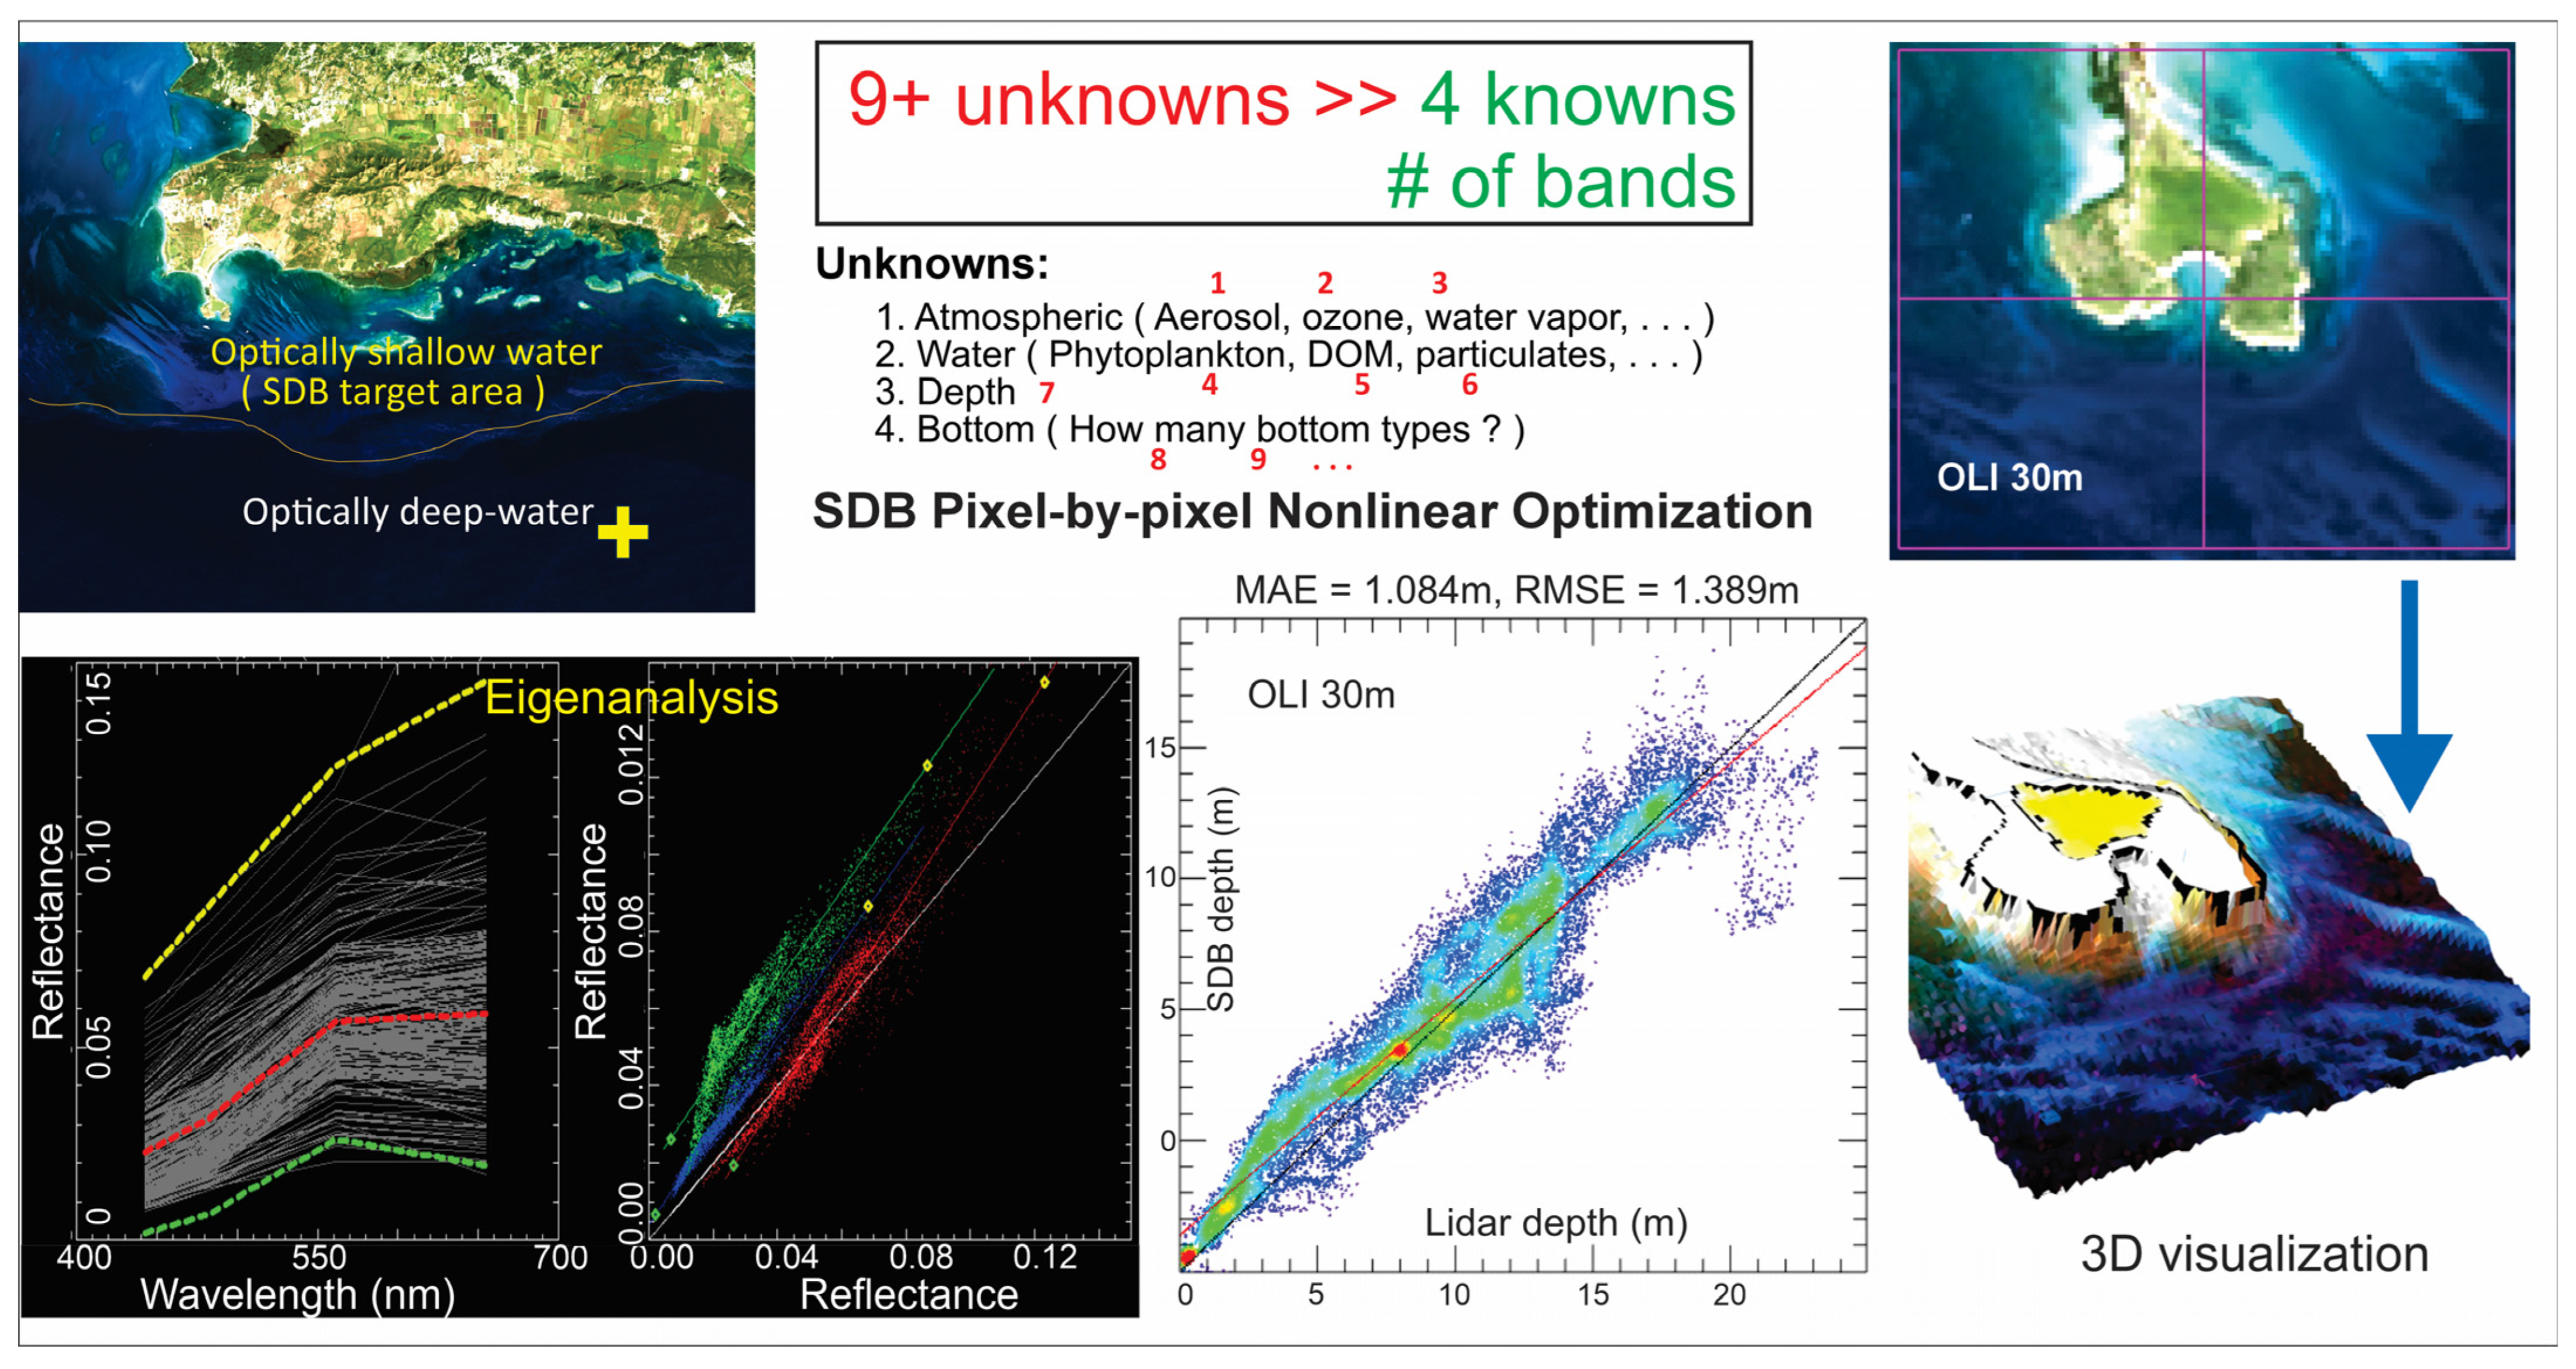
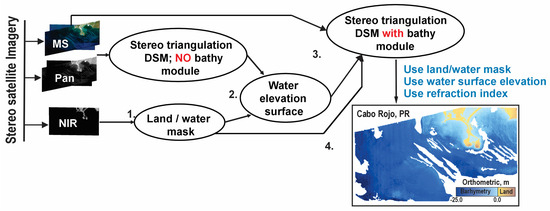
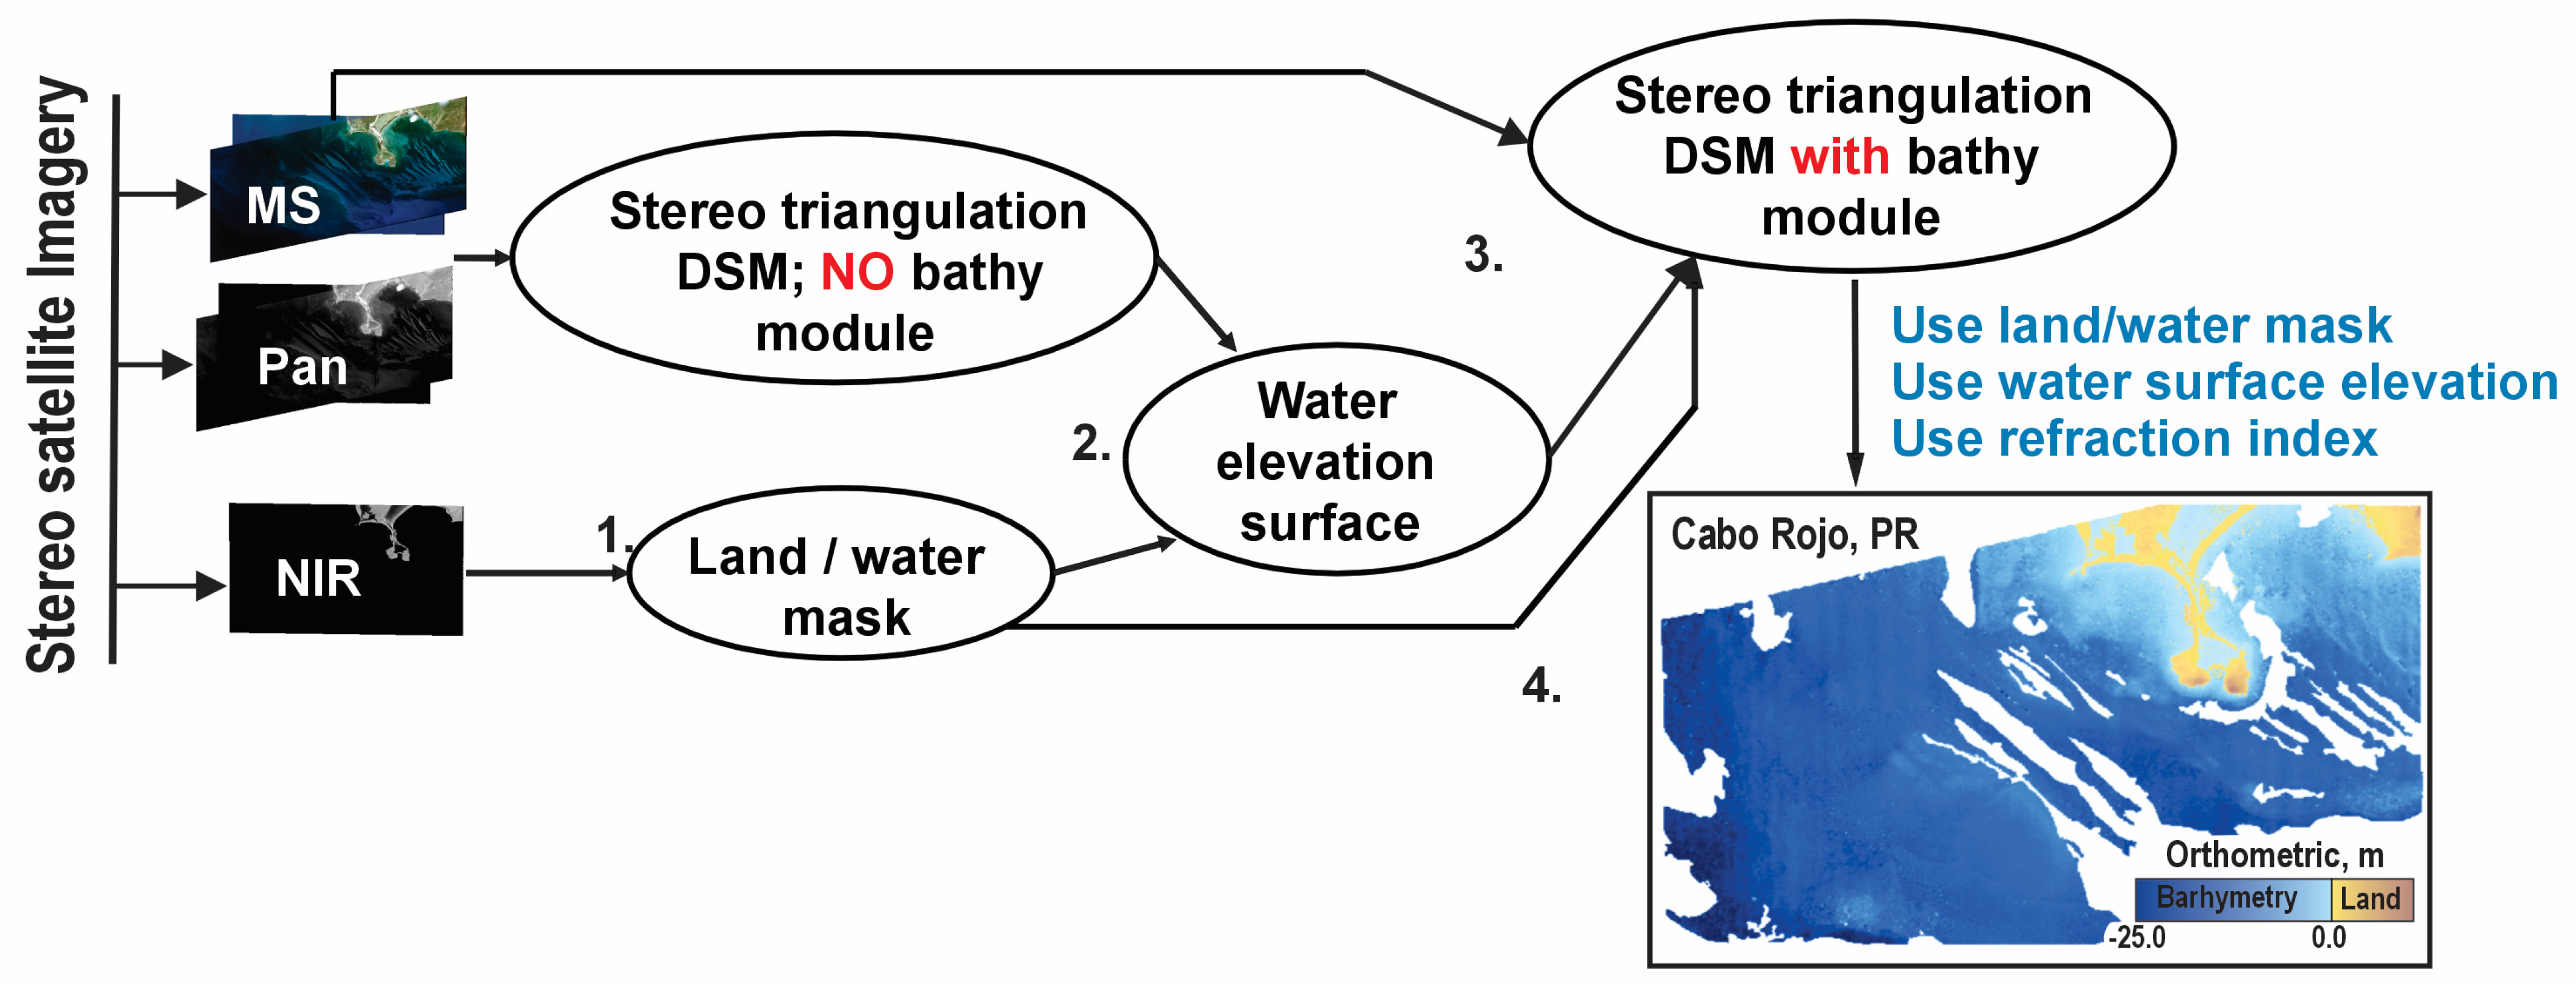
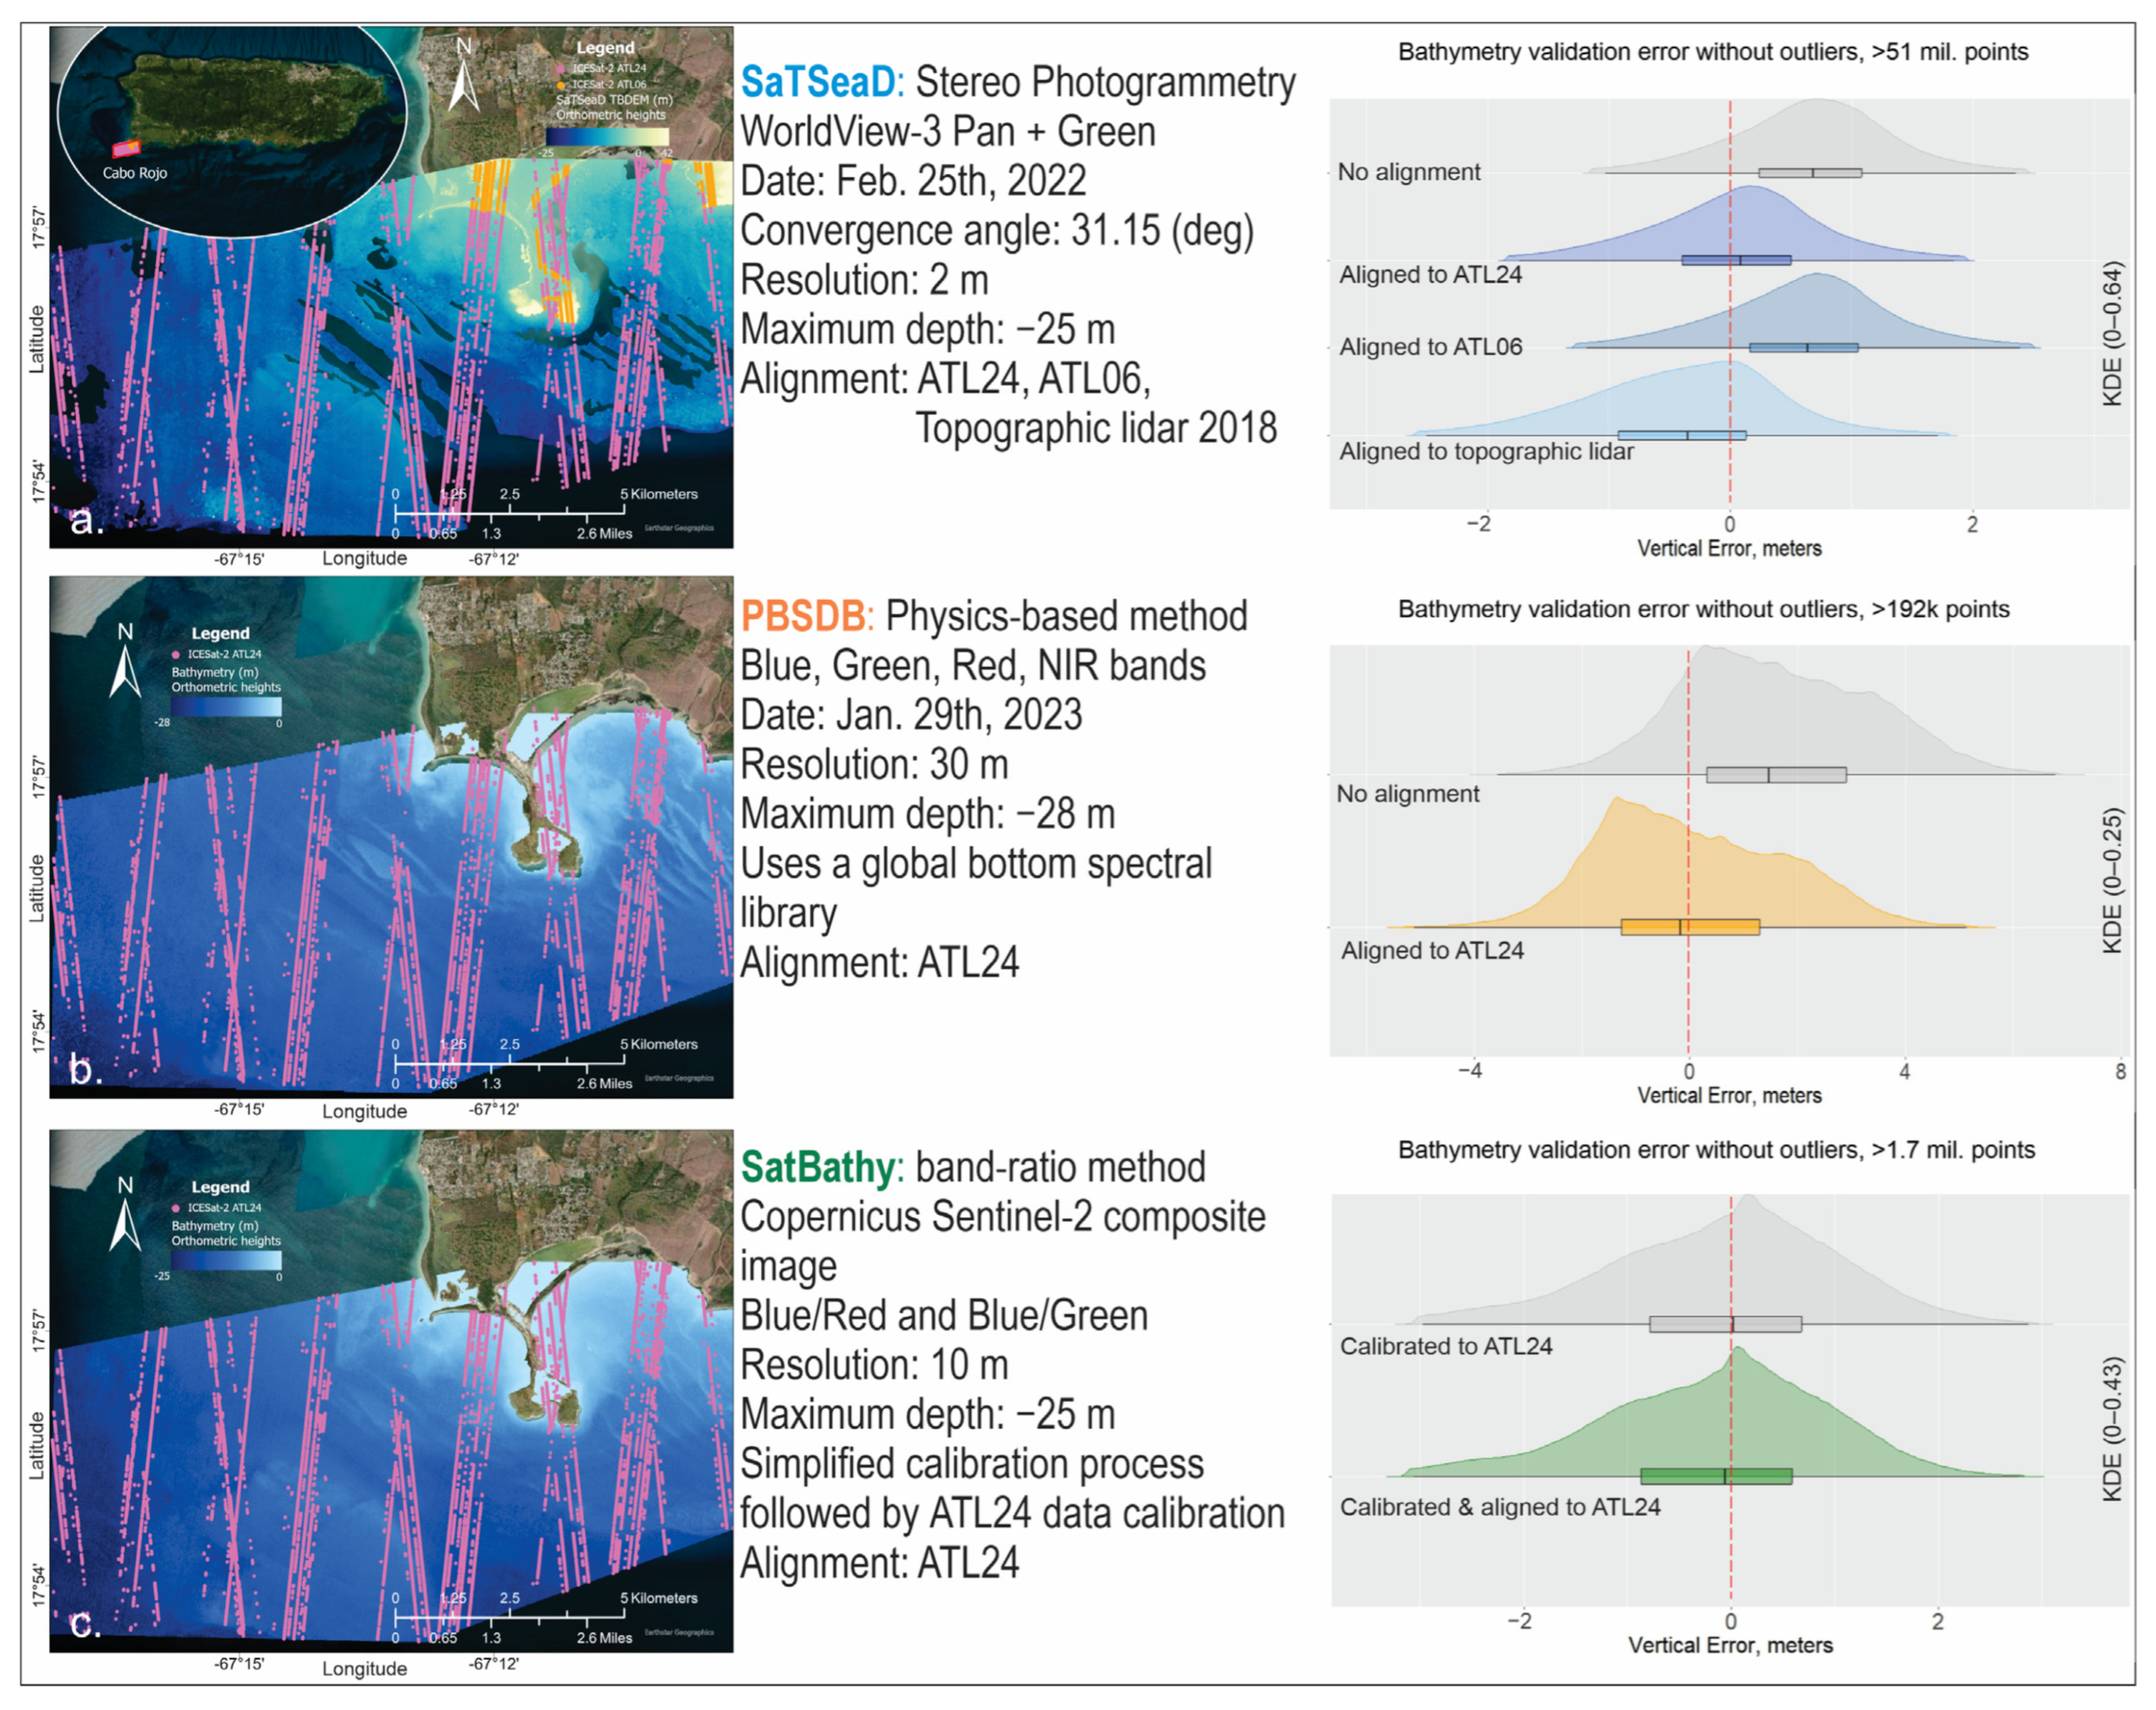
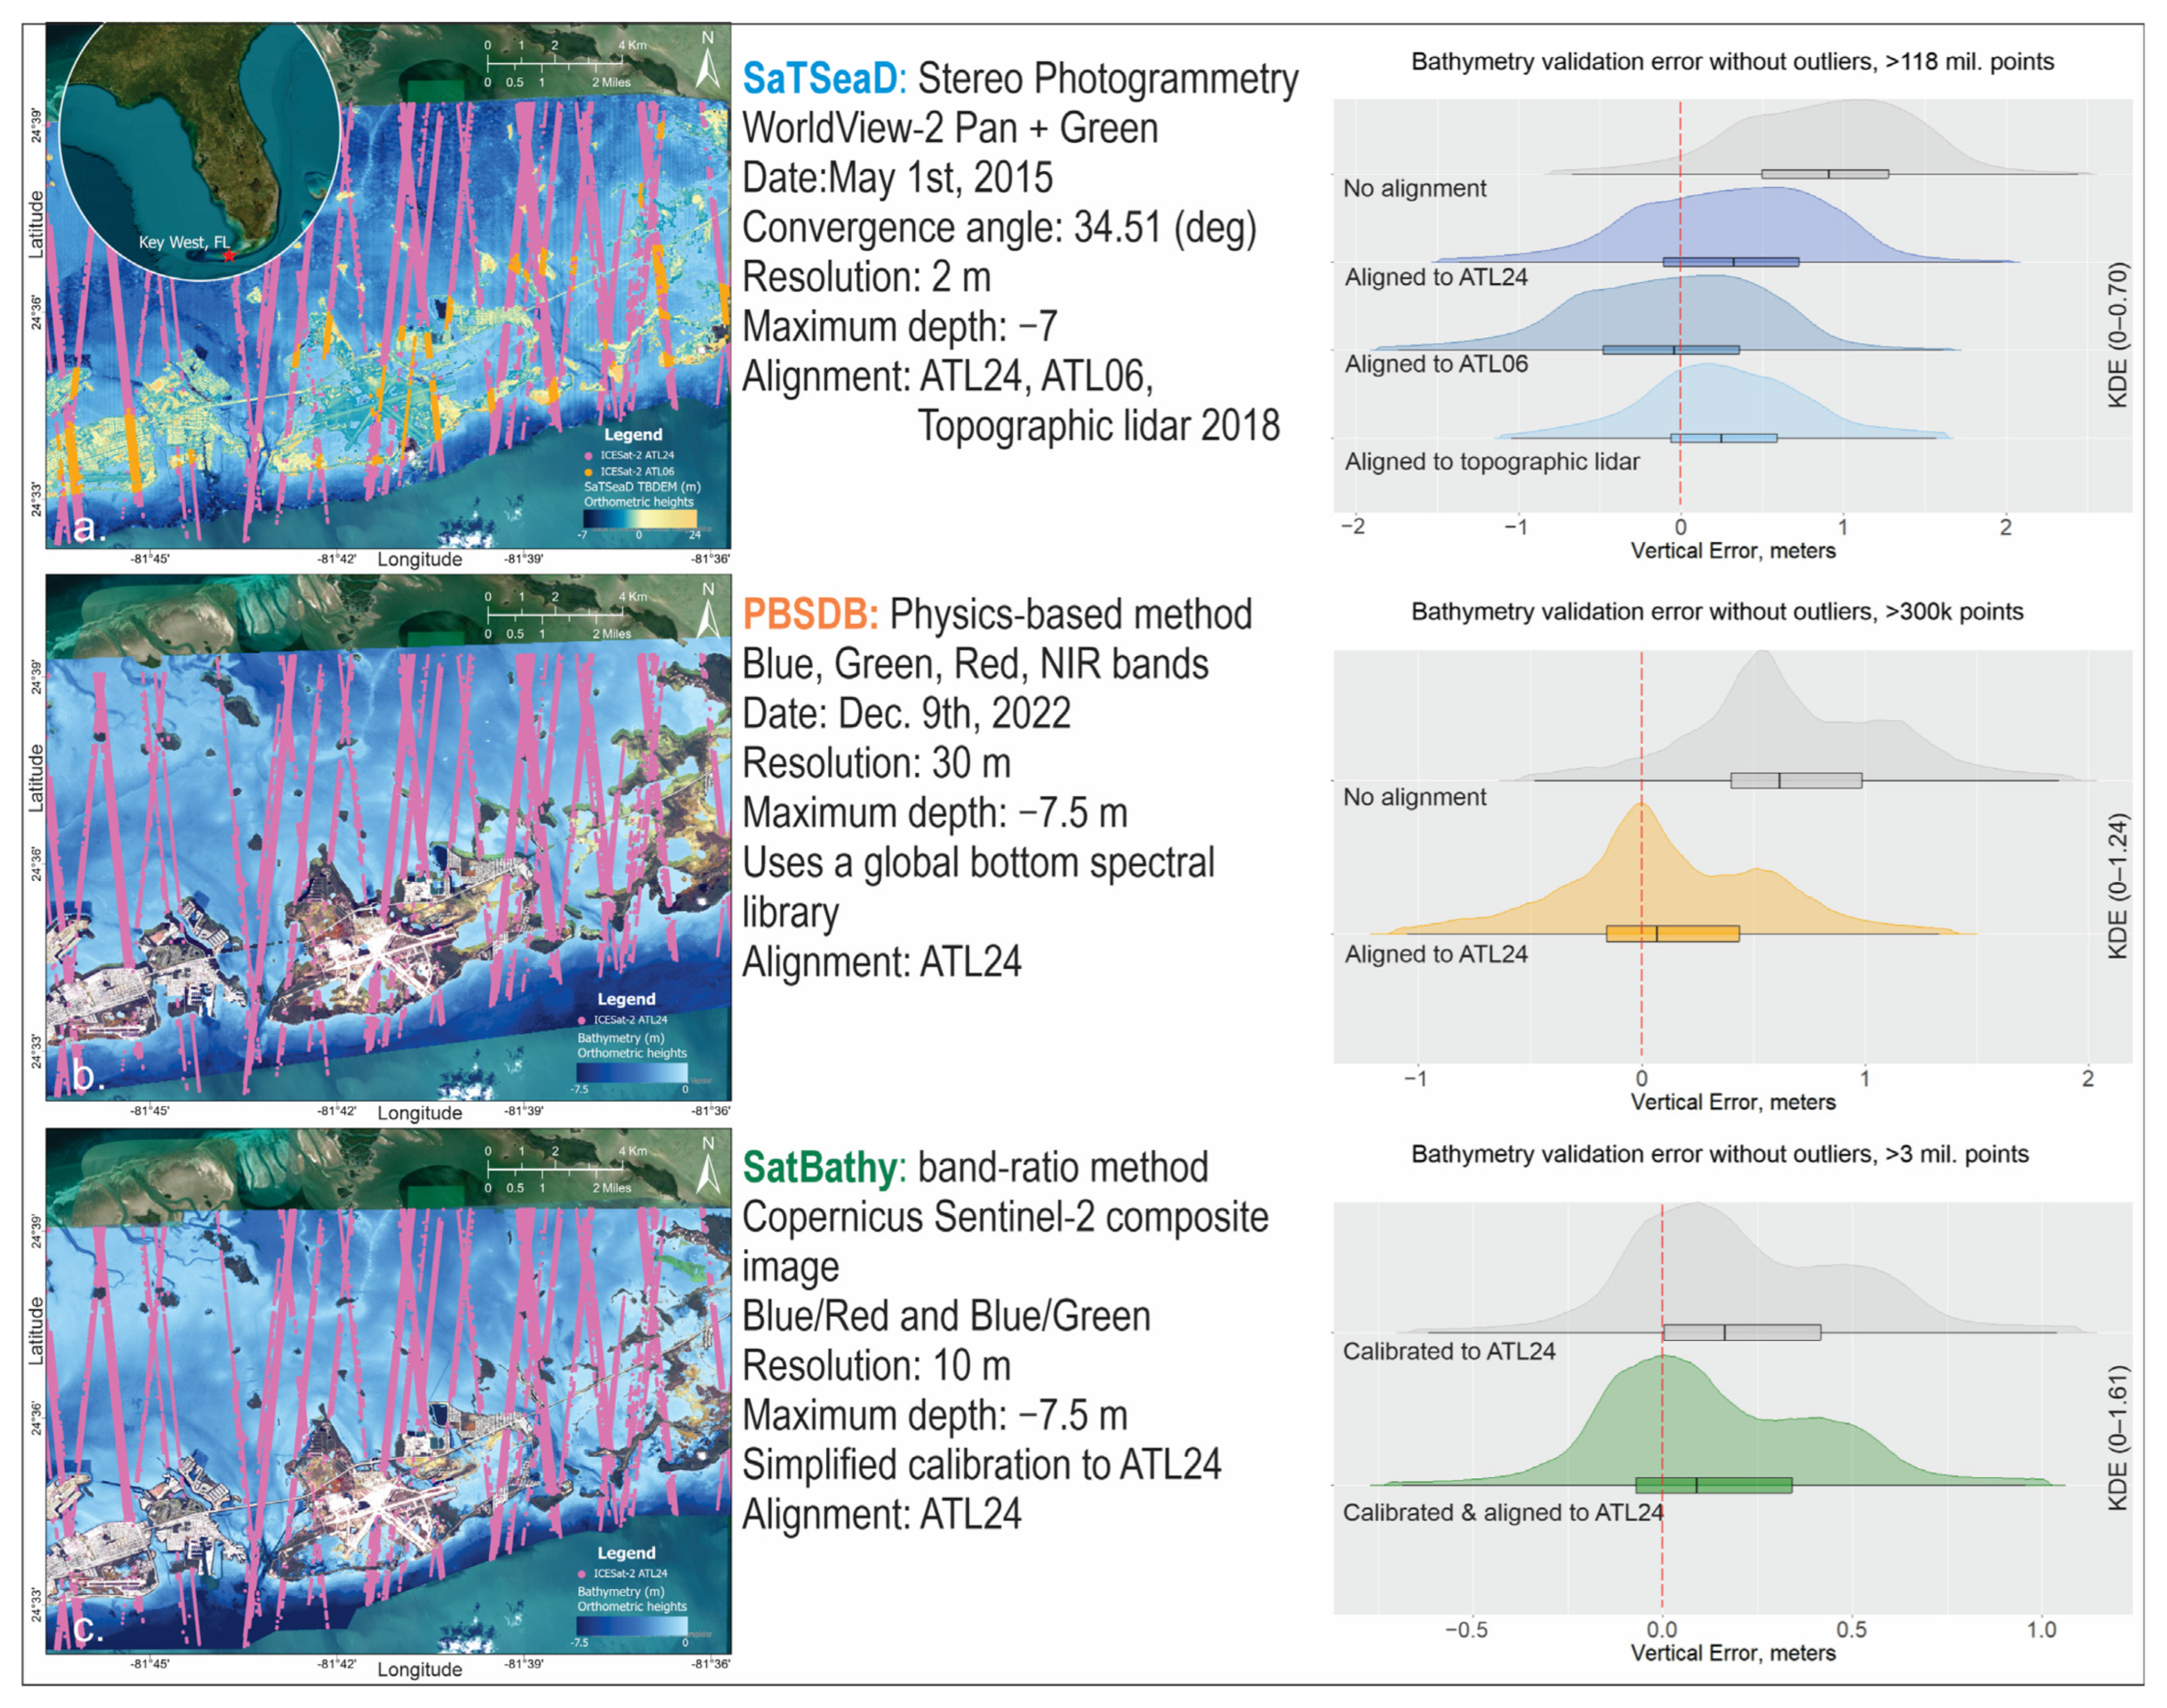
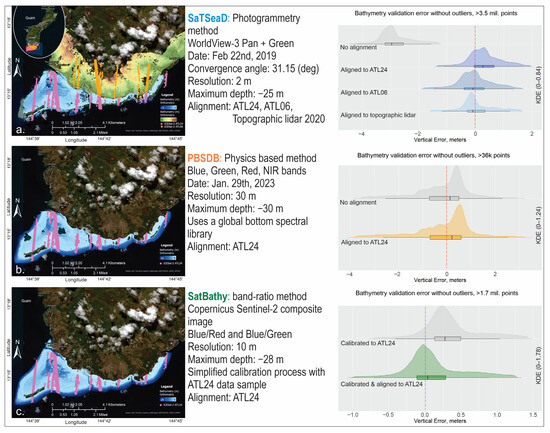
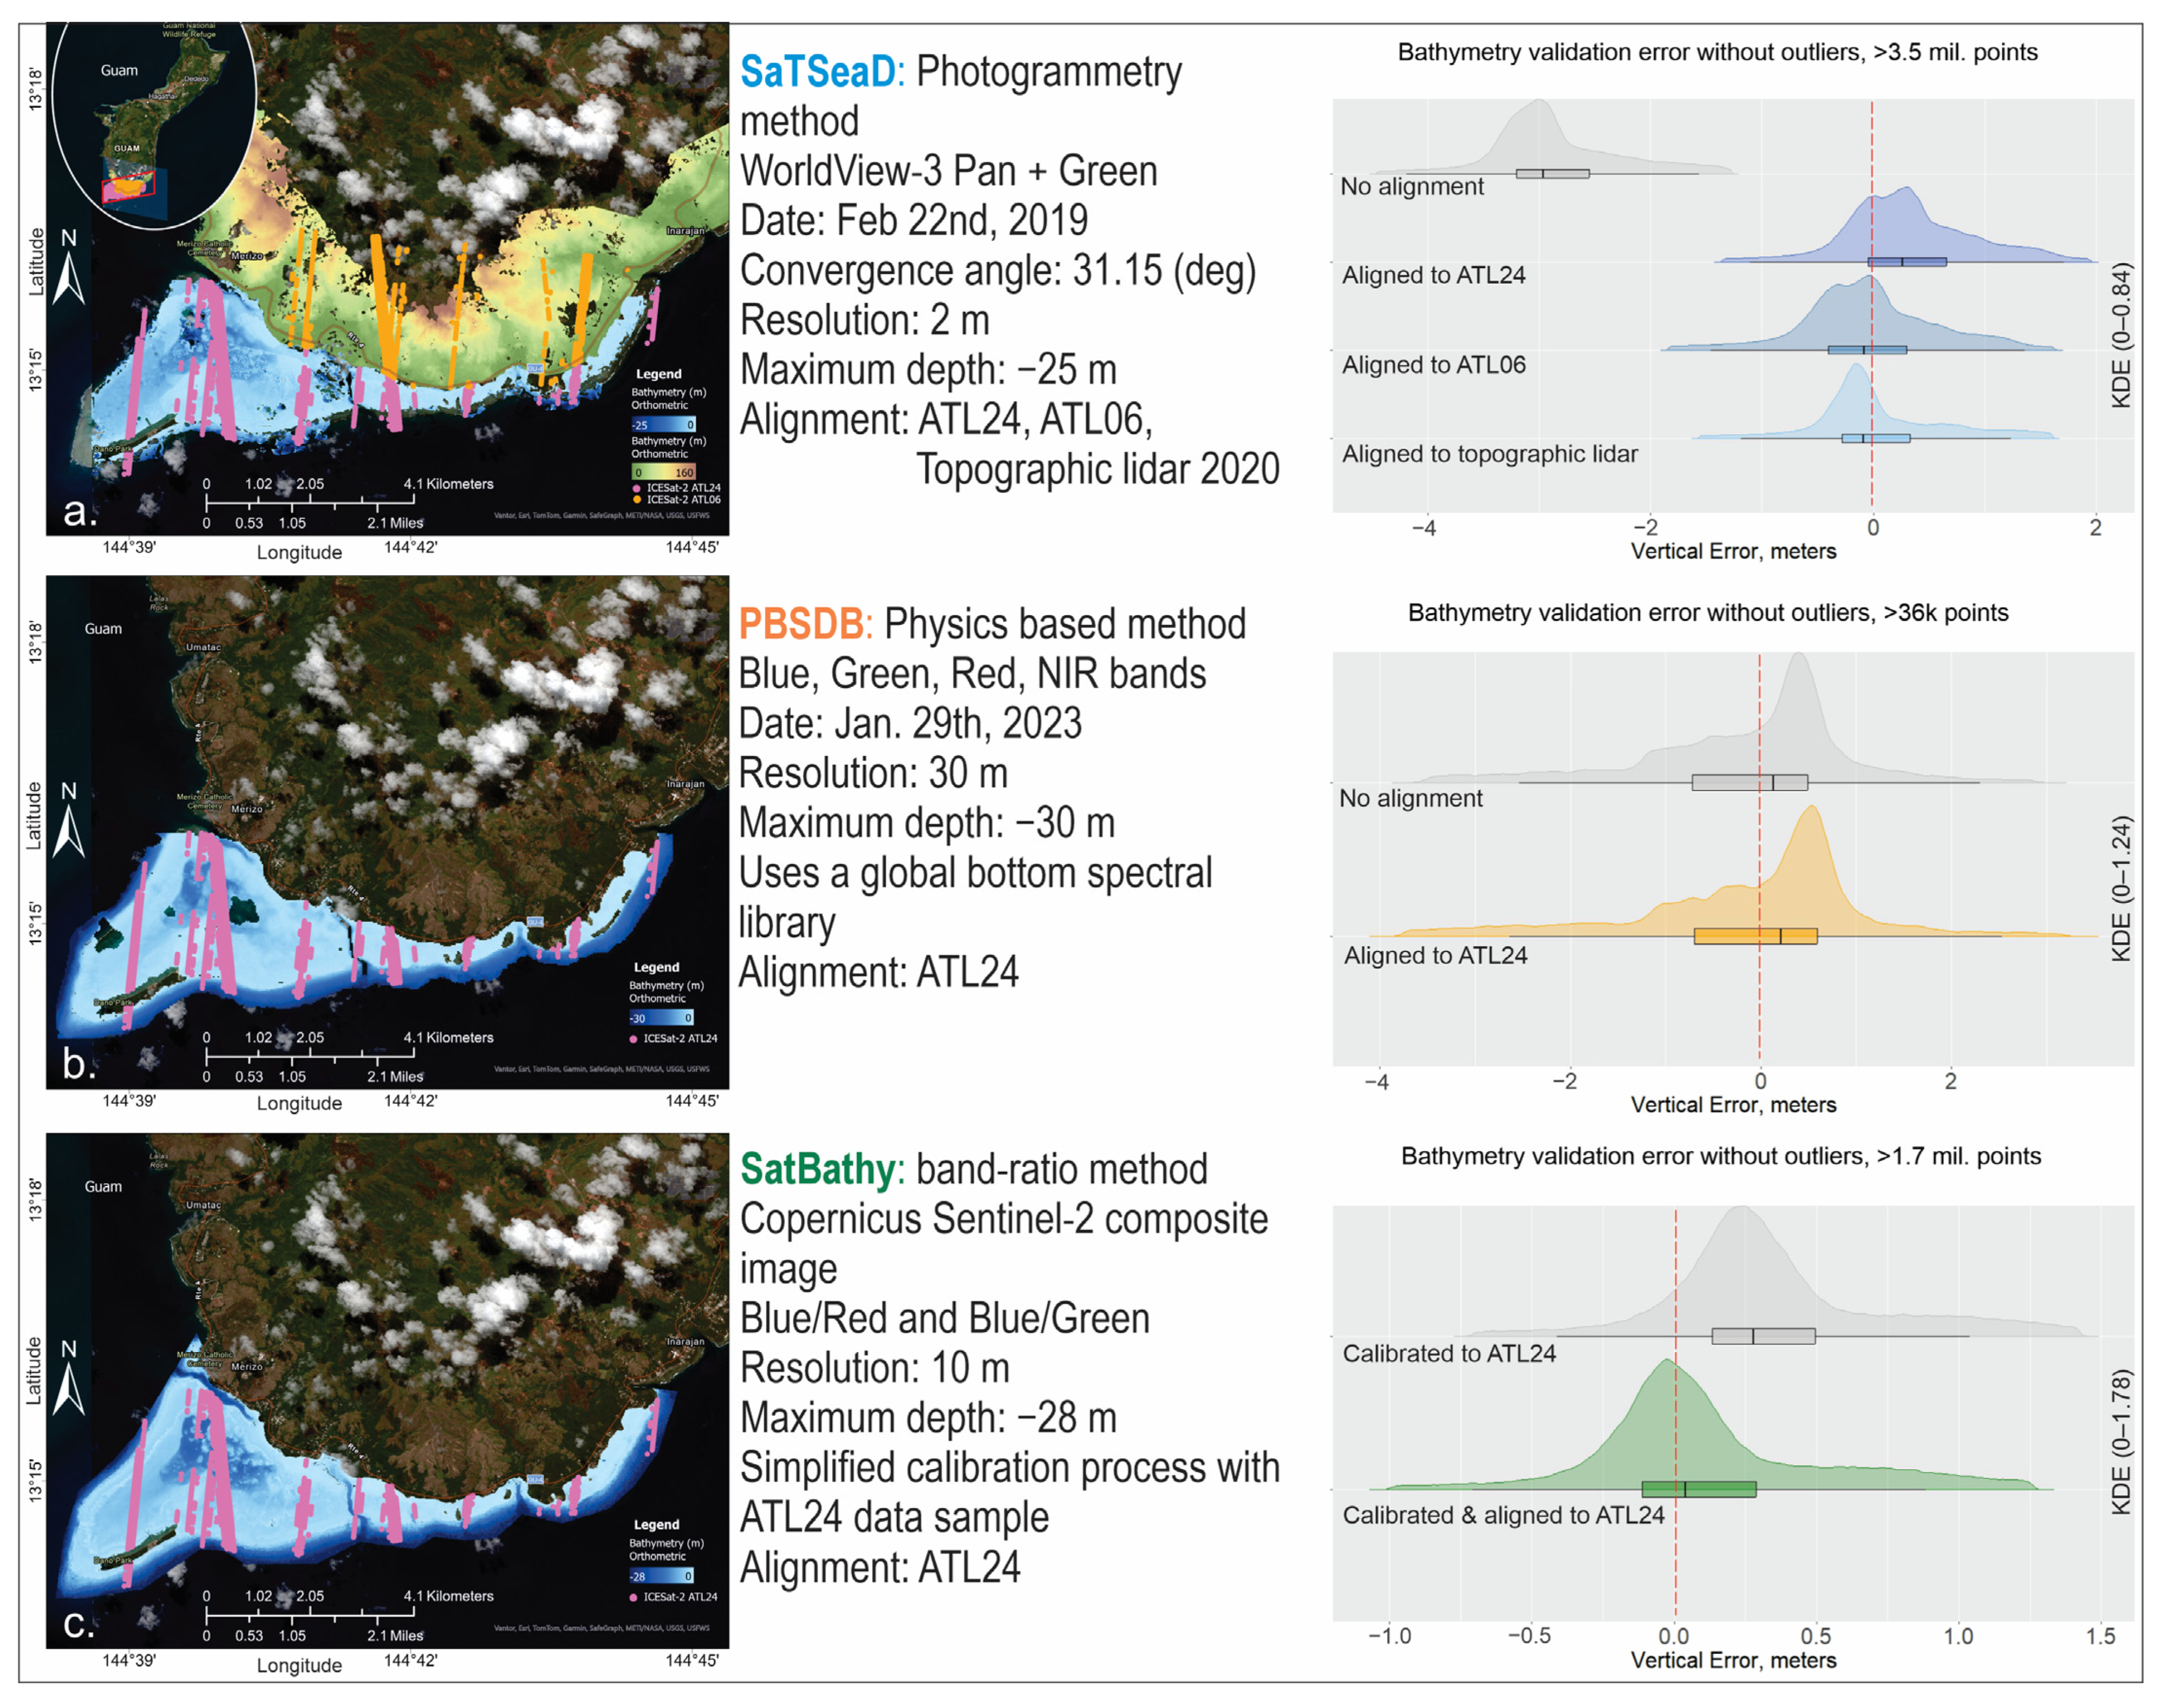
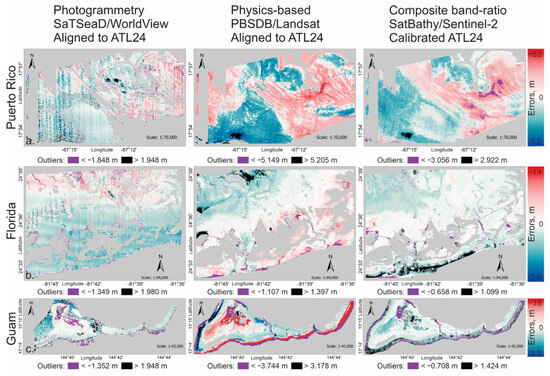
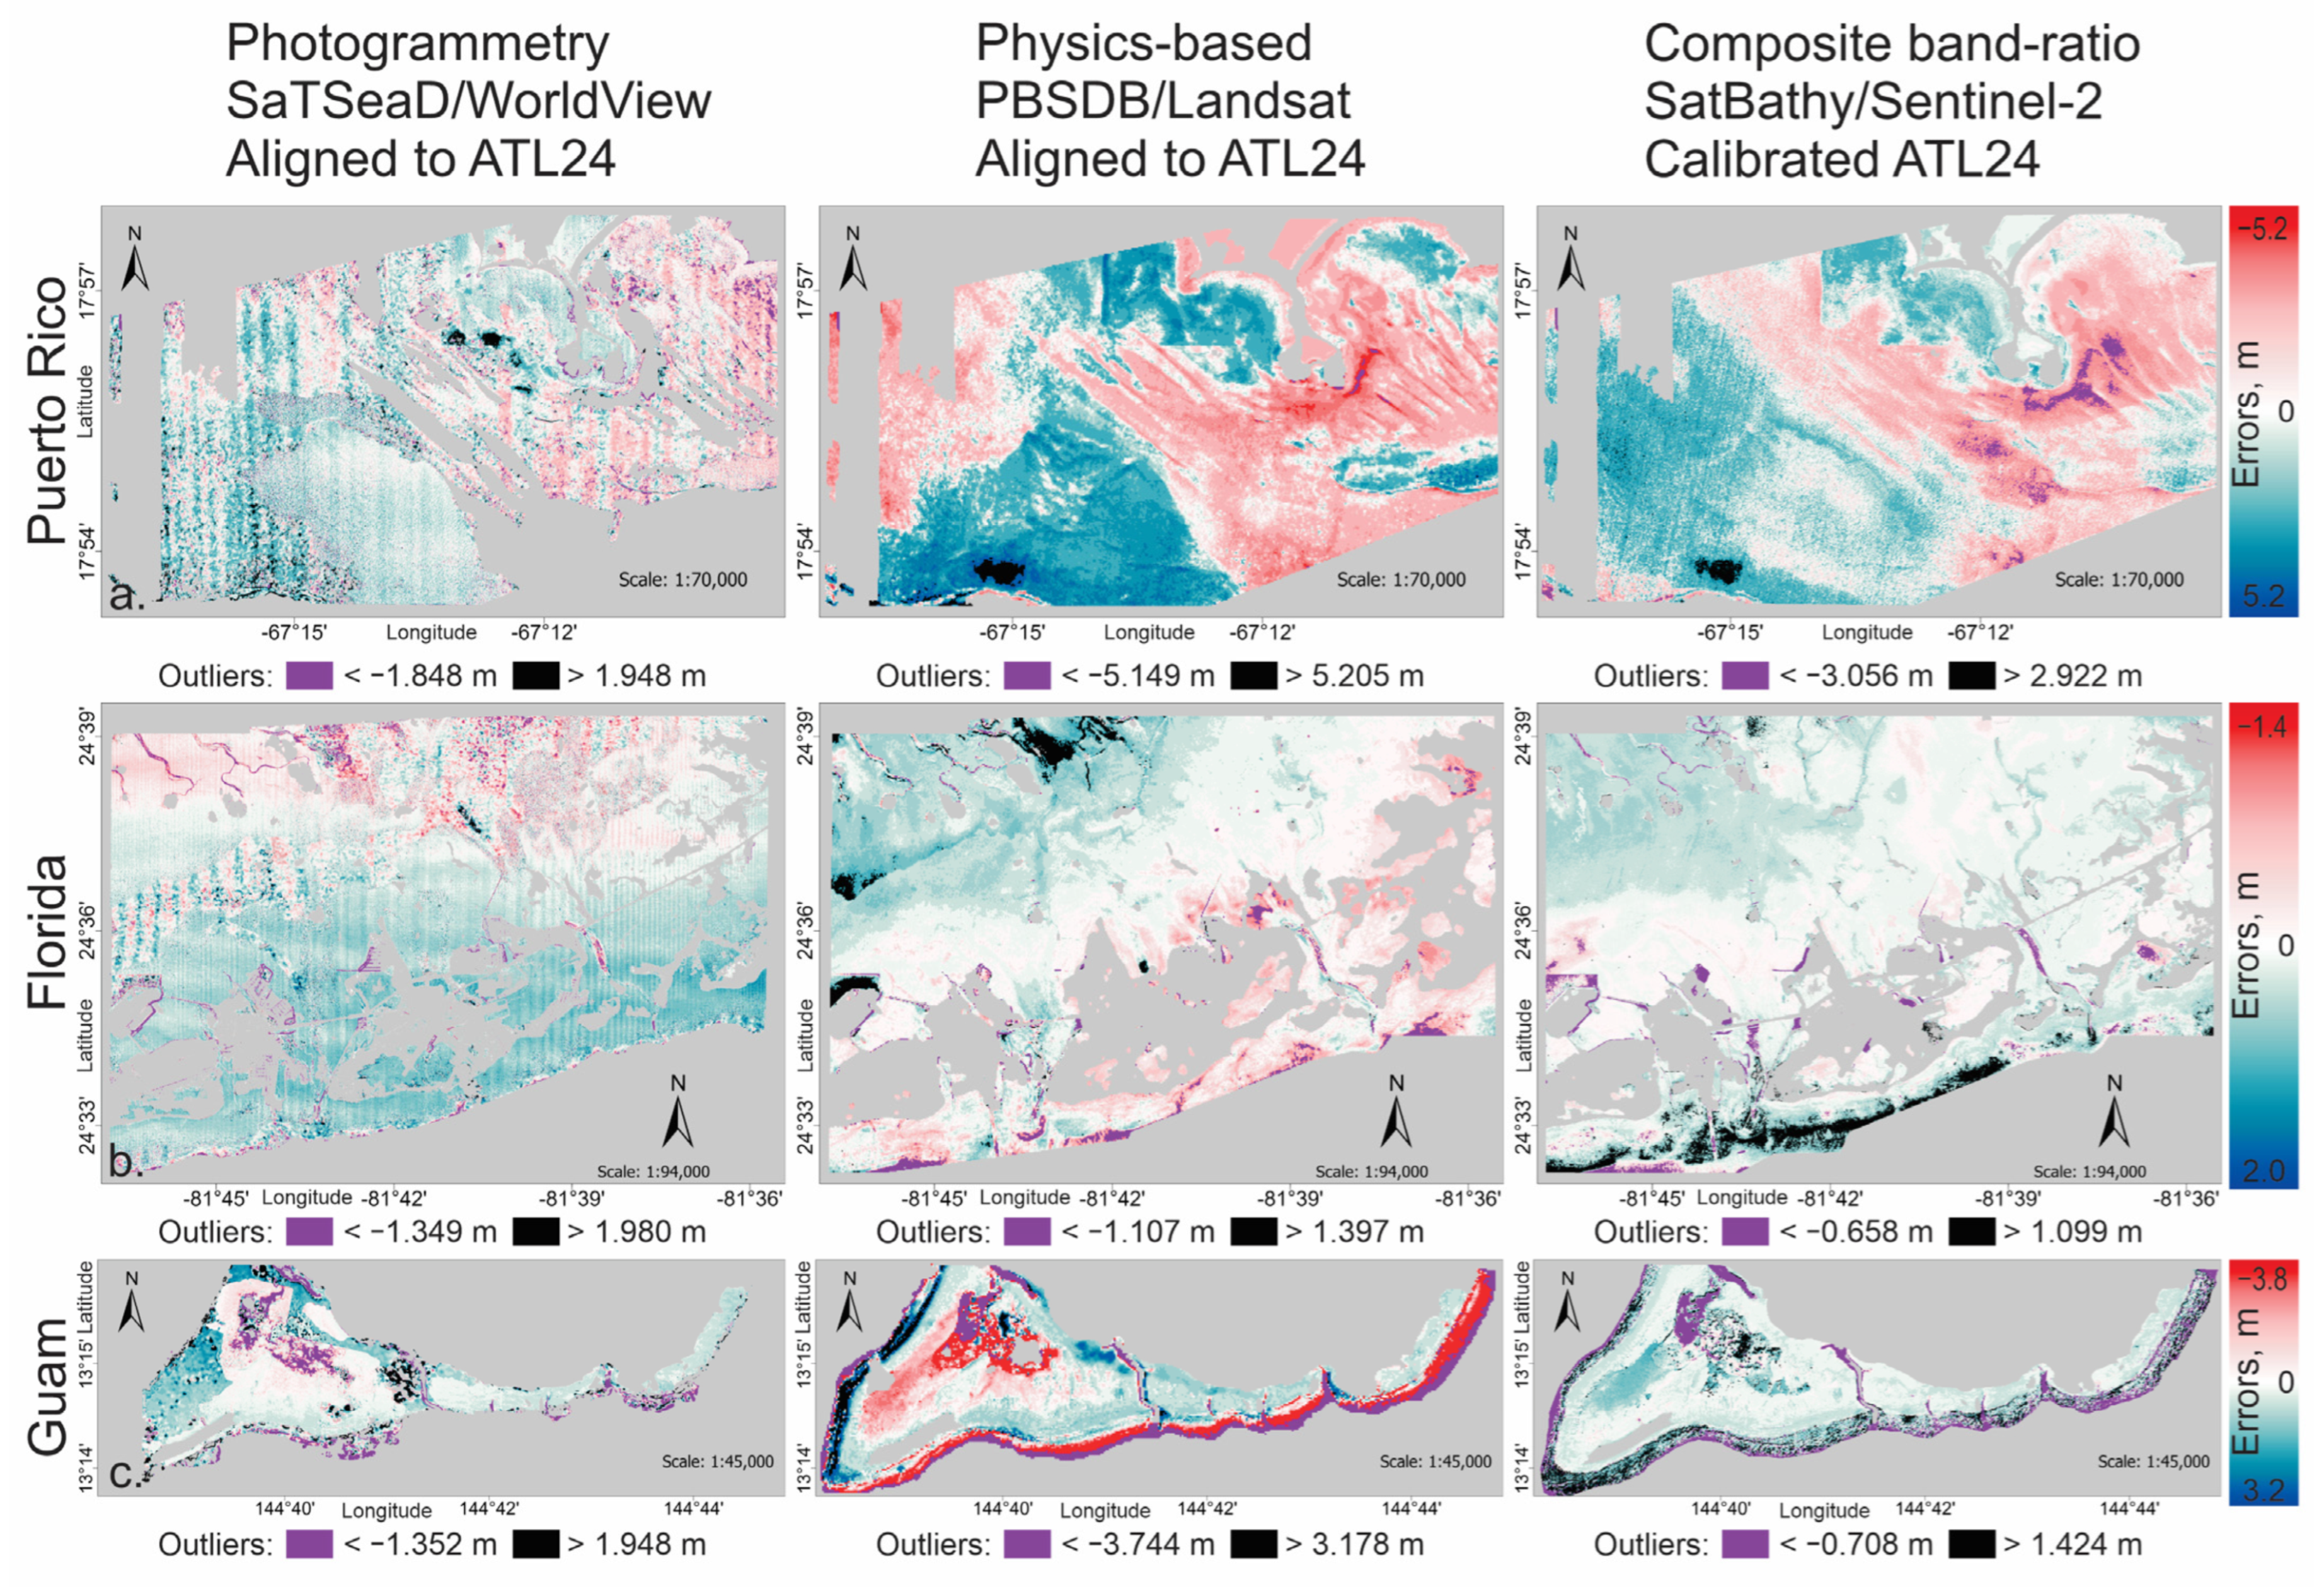
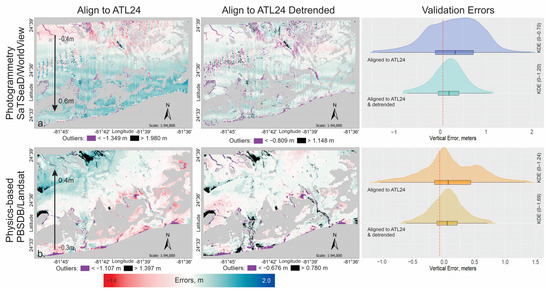

Disclaimer/Publisher’s Note: The statements, opinions and data contained in all publications are solely those of the individual author(s) and contributor(s) and not of MDPI and/or the editor(s). MDPI and/or the editor(s) disclaim responsibility for any injury to people or property resulting from any ideas, methods, instructions or products referred to in the content. |
© 2026 by the authors. Licensee MDPI, Basel, Switzerland. This article is an open access article distributed under the terms and conditions of the Creative Commons Attribution (CC BY) license.