


Abstract
This study introduces a novel strategy for optimizing hybrid drone-and-truck delivery systems in remote areas by leveraging geospatial analytics. Geospatial methods are employed to identify optimal depot and drone nest locations, which serve as critical nodes for efficient delivery operations. After determining these locations, a customized Vehicle Routing Problem (VRP) model is applied to solve the routing problem. We use Network Analyst (NA) from ArcGIS Pro to solve the VRP problem and improve the solution by customizing the algorithm so that all delivery orders for a vehicle are geographically clustered within the service area. Comparative analysis between truck-only and hybrid truck-and-drone scenarios reveals significant efficiency gains, including reductions in delivery routes, on-road minutes, and total miles traveled. A case study conducted in parts of Wyoming, Idaho, Nevada, Utah, and Colorado validates these findings. The results demonstrate a 10.5% reduction in delivery routes, a 15% reduction in on-road minutes, and a 28% decrease in total miles. Further improvements were achieved through spatial clustering, optimizing delivery routes by grouping orders geographically. These findings emphasize the potential of hybrid delivery systems to improve logistics in remote areas, providing actionable insights for supply chain decision-makers, highlighting the robustness of the proposed method.
1. Introduction
Efficient delivery systems play a crucial role in overcoming logistics challenges in remote areas. Logistics in remote and rural areas presents unique challenges that differ significantly from those in urban environments. These regions often suffer due to underdeveloped infrastructure, low population density, and varied terrain, which complicate efficient delivery systems [1,2]. The lack of well-maintained roads and the vast distances between delivery points further exacerbate these challenges, making it difficult to ensure timely and cost-effective delivery of goods and services. In rural agricultural production, the delivery of means of production (such as fertilizer and machinery) and the collection of produce often result in low utilization of the vehicle load capacity, varying between 10% and 95%. This inefficiency leads to increased transport costs and environmental impacts [3]. Milton et al. [4] pointed out that innovative approaches to improve health service delivery in rural and remote regions encompass organizational restructuring, telehealth utilization, medical transportation optimization, and addressing public health challenges. Reliable logistics systems are crucial in ensuring timely access to supplies and services, improving quality of life and economic opportunities for residents.
To address to these challenges, hybrid delivery systems that combine the capabilities of drones and trucks have emerged as a promising solution. These systems leverage the strengths of both modes of transportation to optimize delivery routes, reduce operational costs, and enhance overall efficiency. Efficient delivery systems, particularly those integrating drones and ground transportation, play a crucial role in overcoming these obstacles by optimizing routes, reducing costs, and improving service quality. This combination can significantly improve delivery speed and reduce costs, making logistics operations more efficient and sustainable.
The use of drones for delivery has gained significant attention due to their potential benefits and inherent limitations. Drone delivery offers significant benefits, including increased speed, efficiency, bypassing traffic congestion, cost-effectiveness, and accessibility, particularly for last-mile logistics [5,6,7]. They are also cost-effective in certain situations, such as delivering medical supplies to remote areas or performing inventory management tasks in large warehouses [8]. Additionally, Kim et al. [9] found that drones contribute to environmental sustainability by reducing the reliance on fossil fuels and lowering carbon emissions. However, there are limitations to the widespread adoption of drones in logistics. Challenges such as payload capacity and regulatory hurdles persist, necessitating a balanced approach to their integration into existing systems [2,10]. Furthermore, concerns over privacy, security, and the potential for accidents need to be addressed to ensure the safe and ethical use of drones [11].
The Vehicle Routing Problem (VRP) is a critical optimization challenge in logistics, focusing on determining the most efficient routes for a fleet of vehicles to deliver goods to various locations. Traditionally, VRP has been applied in truck-based logistics, where the goal is to minimize costs while meeting customer demands [12]. Remote logistics face significant challenges, particularly in rural areas (e.g., Wyoming, Idaho, Nevada, Utah, and Colorado) characterized by long distances, difficult terrain, and inadequate infrastructure. Traditional truck delivery systems often struggle to meet the demands of these environments due to their reliance on road networks, which may be poorly maintained or non-existent. However, VRP has evolved to address modern challenges by integrating drones into delivery systems. Recent adaptations, such as the VRP with Drones proposed by Sadok et al. [13], optimize coordinated delivery routes for trucks and drones working in tandem. Similarly, Sitek et al. [14] introduced the hybrid truck-drone routing problem, which considers dynamic drone take-off points, bidirectional delivery, and diverse shipment types. These adaptations demonstrate the potential of drones to reduce costs and improve delivery times, especially for last-mile logistics in remote areas [15,16,17]. These innovations highlight how VRP models are evolving to leverage the unique capabilities of drones, addressing the challenges posed by traditional truck delivery systems in challenging terrains or infrastructure-deficient regions.
Geospatial analytics, particularly Geographic Information Systems (GIS), have revolutionized logistics operations. GIS play a crucial role in optimizing logistics operations by enhancing route planning, location selection, and network design. These methods enable logistics companies to analyze spatial data effectively, leading to improved decision-making and operational efficiency. GIS facilitates the development of route optimization systems that consider various factors such as traffic conditions, delivery points, and vehicle capacities [18]. The selection of logistics center locations is enhanced through multi-criteria spatial analysis, which evaluates economic and geographical factors to minimize costs. This approach allows for a systematic assessment of potential sites, ensuring that logistics centers are optimally positioned to serve metropolitan areas effectively [19]. These geospatial methods have proven invaluable in addressing complex logistical problems, such as the traveling salesman problem and vehicle routing with time windows [20]. Recent studies have integrated genetic algorithms with ArcGIS Network Analyst to enhance route planning, considering multiple criteria and real-time road networks [21,22]. Geospatial analytics play a crucial role in solving complex logistical problems by providing a comprehensive view of spatial relationships and patterns. This enables logistics companies to make data-driven decisions that improve efficiency, reduce costs, and enhance customer satisfaction.
Hybrid delivery systems integrating drones and trucks offer a promising solution to enhance logistical efficiency and reduce costs. These systems capitalize on the complementary strengths of drones and trucks: drones provide rapid, congestion-free delivery for last-mile logistics, while trucks handle larger payloads over greater distances [2,23]. Recent studies highlight the effectiveness of such systems in improving delivery efficiency, reducing costs, and addressing remote logistics challenges, such as long distances and difficult terrains [24,25]. Chen et al. [26] showed that hybrid systems enhance service quality through route optimization and resource utilization. Studies suggest that these systems can reduce operational costs by up to 30% compared to traditional truck-only systems [27,28], making them particularly valuable for humanitarian logistics and remote deliveries [29]. Innovative models propose that trucks act as mobile depots, with drones handling final deliveries, thus overcoming obstacles like remote locations and challenging terrains [30,31]. Zhang et al. [32] classified truck-drone cooperation into four modes: parallel, mixed, drone-assisted truck delivery, and truck-assisted drone delivery. Despite these advancements, challenges such as regulatory barriers and technological limitations must be addressed for widespread adoption of these systems, paving the way for sustainable and efficient logistics operations. Table 1 provides a comparative summary of key studies on hybrid truck–drone delivery systems, highlighting their primary contributions and limitations and positioning the current study within this evolving research landscape.
Table 1.
Summary of key literature on hybrid truck–drone delivery systems.
Most existing VRP and drone delivery studies focus on urban or suburban areas with dense demand and strong infrastructure. Remote regions face different challenges, including sparse populations, poor road networks, and difficult terrain. As a result, urban-optimized algorithms often perform poorly in these settings. This study addresses that gap by developing a hybrid model tailored to the logistical and geographical realities of remote delivery.
Research Gaps and Contributions of This Study
Despite significant advances in the integration of drones and trucks for logistics, several gaps persist in the existing research. Although previous studies have explored hybrid truck-drone systems, there is a lack of comprehensive approaches that leverage geospatial analytics for the precise identification of optimal depot and drone nest locations. Many existing models do not adequately consider the spatial data analysis needed to maximize efficiency in remote, geographically diverse areas. While hybrid delivery systems have been studied, most research has focused on urban or suburban environments. There is limited analysis on how these systems can be effectively adapted to the unique challenges of remote and rural areas, which often have sparse infrastructure and longer delivery distances. Additionally, studies applying the VRP to hybrid systems often rely on standard models that may not fully address the specific operational requirements of combined drone-truck logistics.
While many papers highlight the benefits of hybrid delivery systems, few provide detailed quantitative comparisons between hybrid models (drones and trucks) and traditional truck-only solutions. There is a need for more empirical evidence to demonstrate the actual performance improvements in terms of time and distance savings. Addressing these gaps can pave the way for more effective and sustainable logistics solutions.
The primary objective of this study is to develop and validate a geospatially informed hybrid delivery model that integrates drones and trucks for efficient last-mile delivery in remote areas. Unlike previous research focused on urban or suburban contexts, this study specifically targets sparsely populated regions with limited infrastructure. It introduces the use of cargo drones for long-haul transport and trucks for last-mile distribution. The study leverages geospatial analytics to identify optimal depot and drone nest locations and integrates these insights into a customized Vehicle Routing Problem (VRP) model. This data-driven framework enhances delivery efficiency, reduces travel distances, and improves route optimization across portions of Wyoming, Idaho, Nevada, Utah, and Colorado.
To address the identified gaps and guide this study, we pose the following research questions:
- How can a hybrid drone-truck delivery model be optimized to improve last-mile logistics in remote, sparsely populated regions?
- How can geospatial analytics be applied to determine optimal depot and drone nest locations for efficient delivery?
- How does the proposed hybrid model perform compared to traditional truck-only delivery in terms of total travel distance, delivery time, and route efficiency?
- What operational trade-offs and practical considerations arise when implementing hybrid delivery systems in infrastructure-limited areas?
This study makes several key contributions to the field of logistics and supply chain management:
- The study introduces a hybrid delivery system that combines the strengths of drones and trucks. This model leverages the speed and flexibility of drones for reaching remote areas and the capacity of trucks for bulk deliveries within high-density zones, offering a comprehensive solution to last-mile delivery challenges in remote regions.
- The study uses geospatial statistical analysis to identify optimal depot and drone nest locations. By conducting hotspot analysis and strategically selecting locations based on delivery demand patterns, the study ensures comprehensive coverage and efficient routing for both drones and trucks.
- The research develops a customized VRP model designed for hybrid delivery operations. This model incorporates the operational structure of depots, trucks, and drone nests, and includes specific customizations to improve route planning by clustering delivery orders within service areas. This approach enhances operational efficiency and reduces travel distances.
- The research validates the proposed hybrid delivery model through a case study based on the road network in portions of Wyoming, Idaho, Nevada, Utah, and Colorado. This case study provides practical insights and demonstrates the real-world applicability of the model, highlighting significant efficiency gains, including reductions in delivery routes, on-road minutes, and total miles traveled.
- The study conducts a comparative analysis between truck-only and hybrid truck-and-drone delivery scenarios. By evaluating metrics such as total delivery time, distance traveled, and the number of delivery routes required, the research provides a comprehensive assessment of the hybrid model’s effectiveness.
Unlike prior studies that focus on urban networks or generic VRP formulations, this research develops a hybrid optimization model specifically for remote, infrastructure-limited areas. The model is informed by geospatial analysis and provides both methodological advancements and empirical validation.
The exposition of this paper is as follows. Section 2 outlines the problem and the methodology employed in this study. Section 3 presents a series of computational experiments to derive managerial insights and assess the performance of the algorithms. Finally, Section 4 presents the significance of the findings, and Section 5 concludes the paper and suggests directions for future research.
2. Methodology
This section addresses the challenges associated with last-mile delivery in remote and rural areas through the implementation of a hybrid truck-and-drone system. It provides a comprehensive overview of the problem, elaborates on the data preparation and geospatial analysis processes, describes the customized vehicle routing solution, and concludes with a comparative analysis of our proposed method against traditional delivery systems.
2.1. Problem Definition
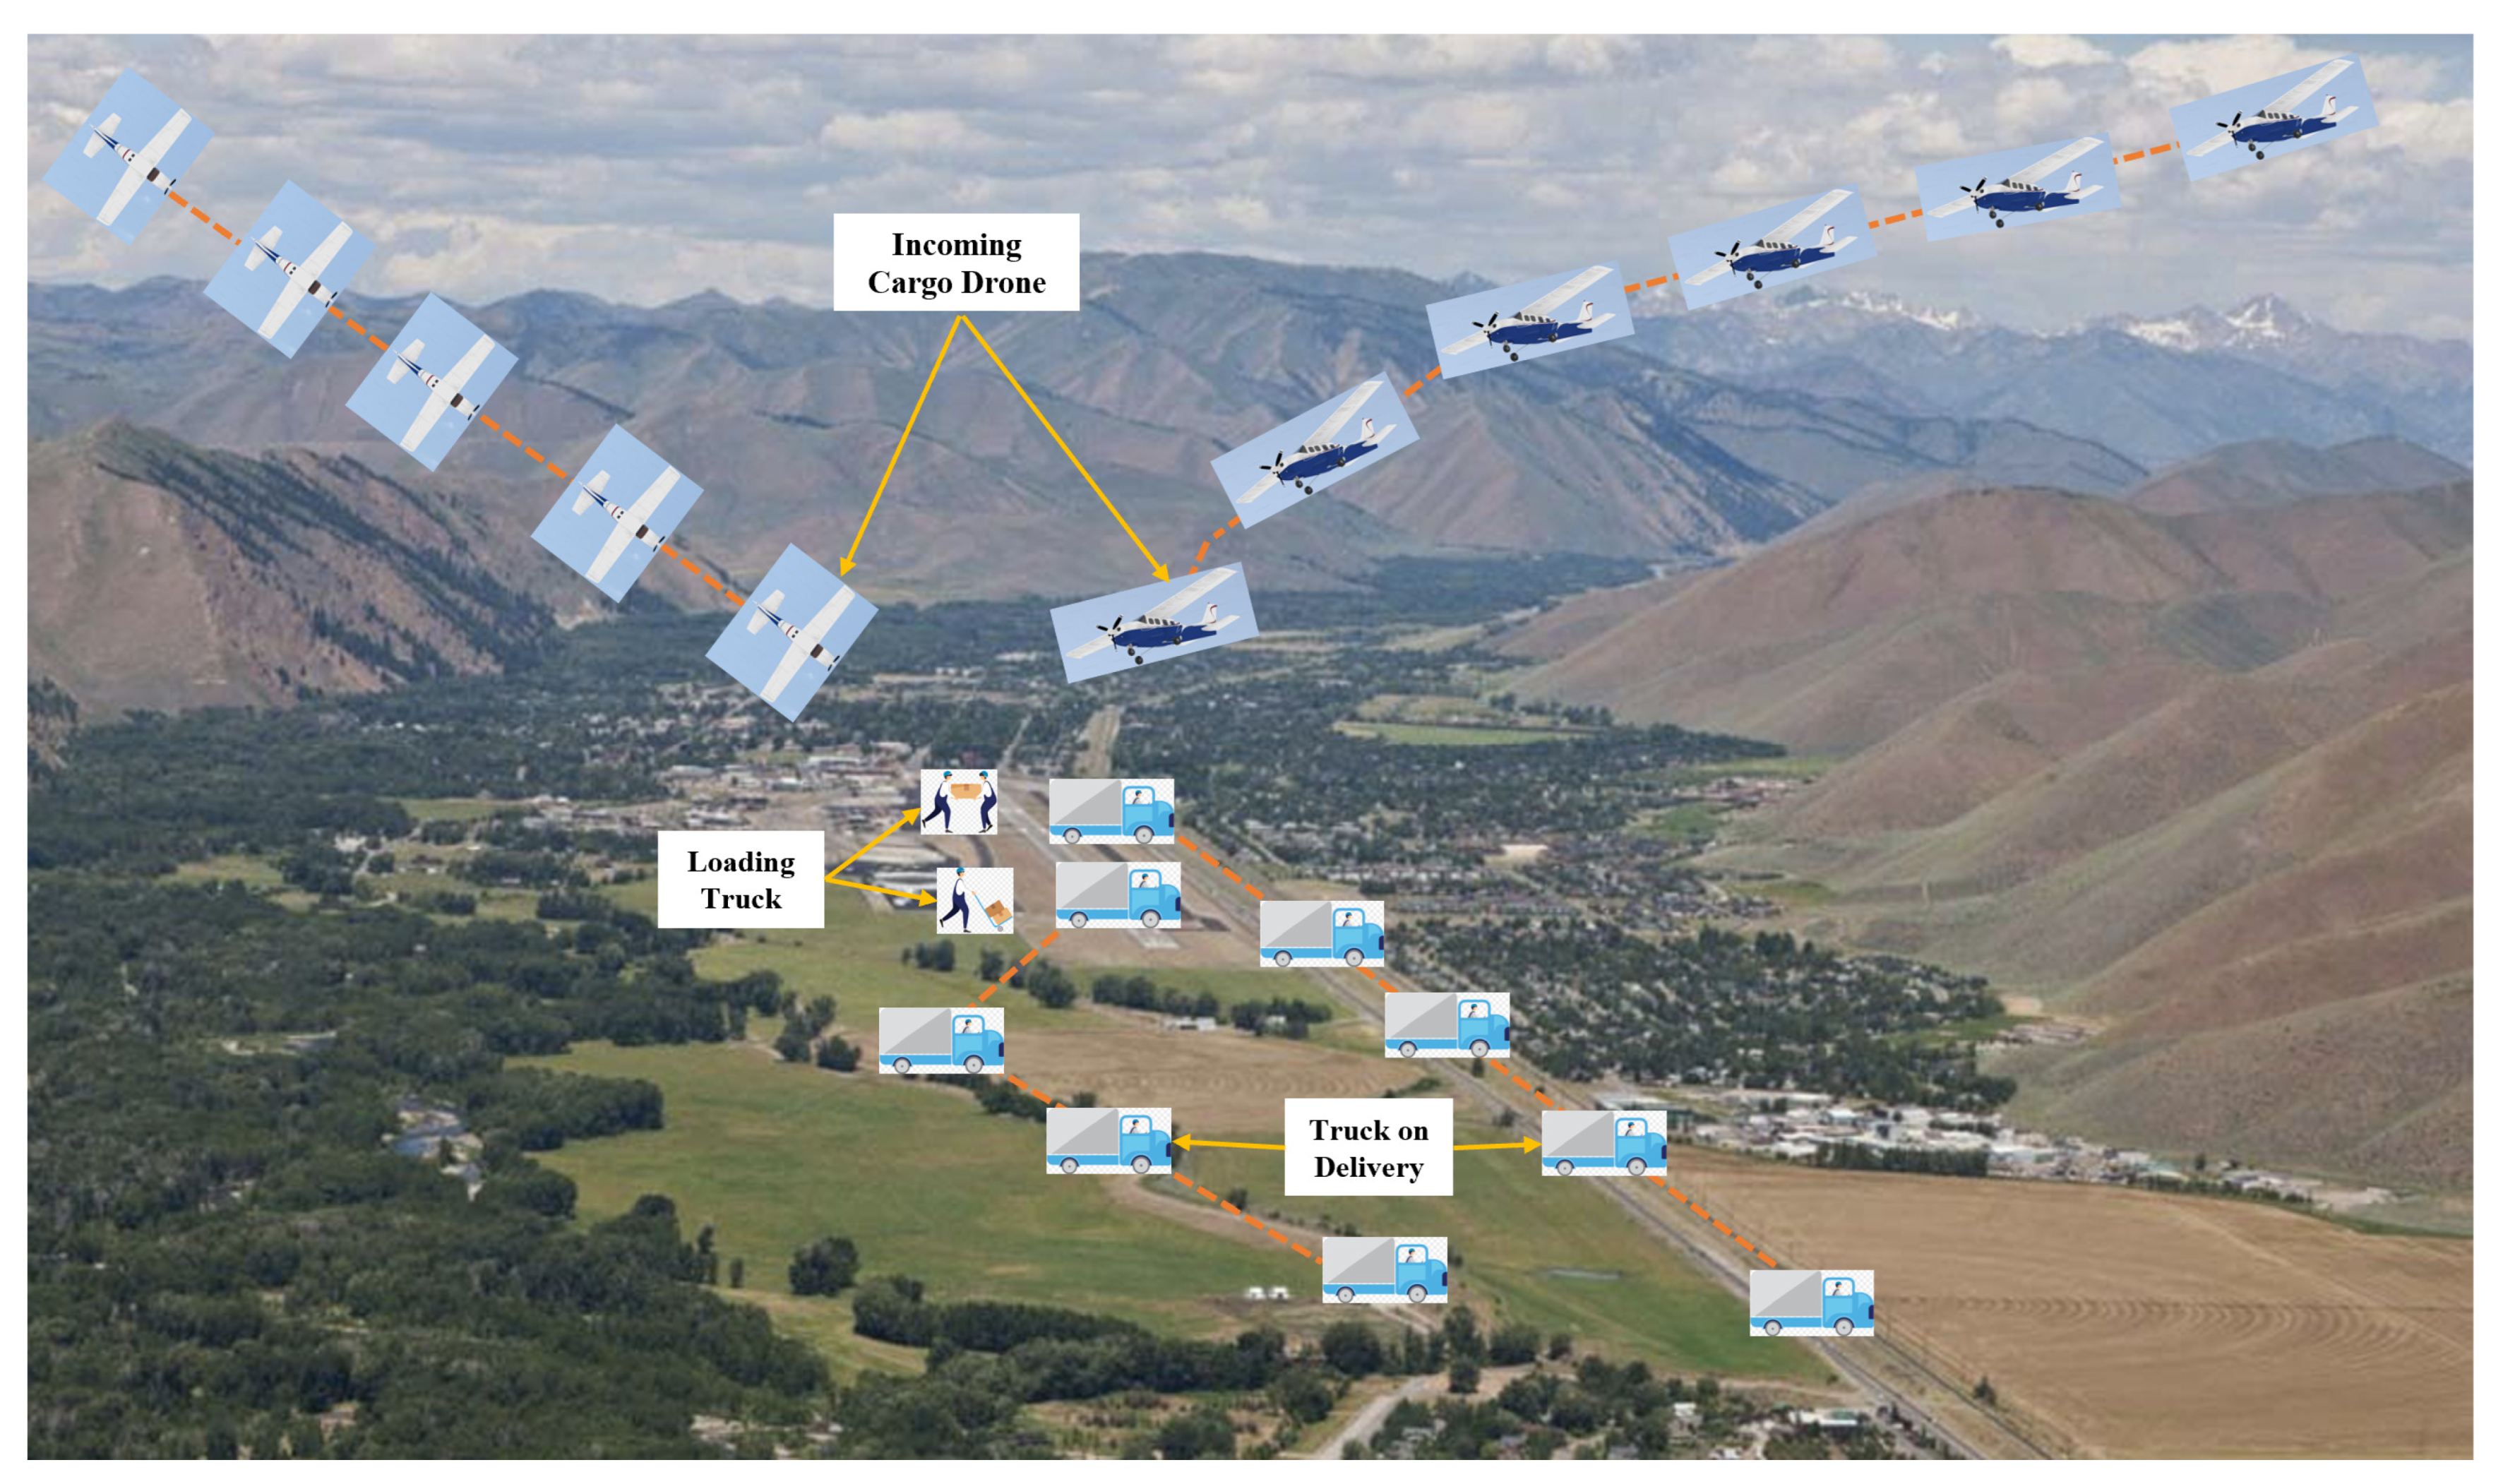
This study proposes a hybrid delivery model to optimize logistics in remote areas by integrating drones and trucks to improve the efficiency of last-mile delivery. The hybrid delivery system leverages the complementary strengths of drones and trucks. Trucks handle bulk deliveries within nearby service areas, while cargo drones operate between depots and drone nests, transferring packages to remote locations. This operational framework ensures efficient allocation of resources and reliable delivery across diverse geographic conditions. The research focuses on regions within Wyoming, Idaho, Nevada, Utah, and Colorado—areas characterized by logistical challenges such as low population density, rugged terrain, and inadequate infrastructure. By addressing these challenges, the proposed hybrid system aims to demonstrate a scalable and effective solution for overcoming the limitations of traditional truck-only delivery methods in rural and remote settings. Figure 1 illustrates the operational workflow of the hybrid truck-and-drone delivery system. Cargo drones transport packages from central depots to drone nests situated in remote, hilly areas. Delivery trucks are then loaded at these drone nests to distribute packages to nearby remote locations, ensuring efficient coverage across challenging terrains.
Figure 1.
Hybrid truck-and-drone delivery network in remote areas.
2.2. Data Preparation and Geospatial Statistical Analysis
The analysis begins with data preparation, utilizing parcel data to identify delivery addresses and census data to provide population information at the block group level. We perform a spatial join between the point parcel feature and polygon census data to obtain information at the address level. This spatial join integrates these datasets to calculate delivery demand by location, revealing service needs across the study region.
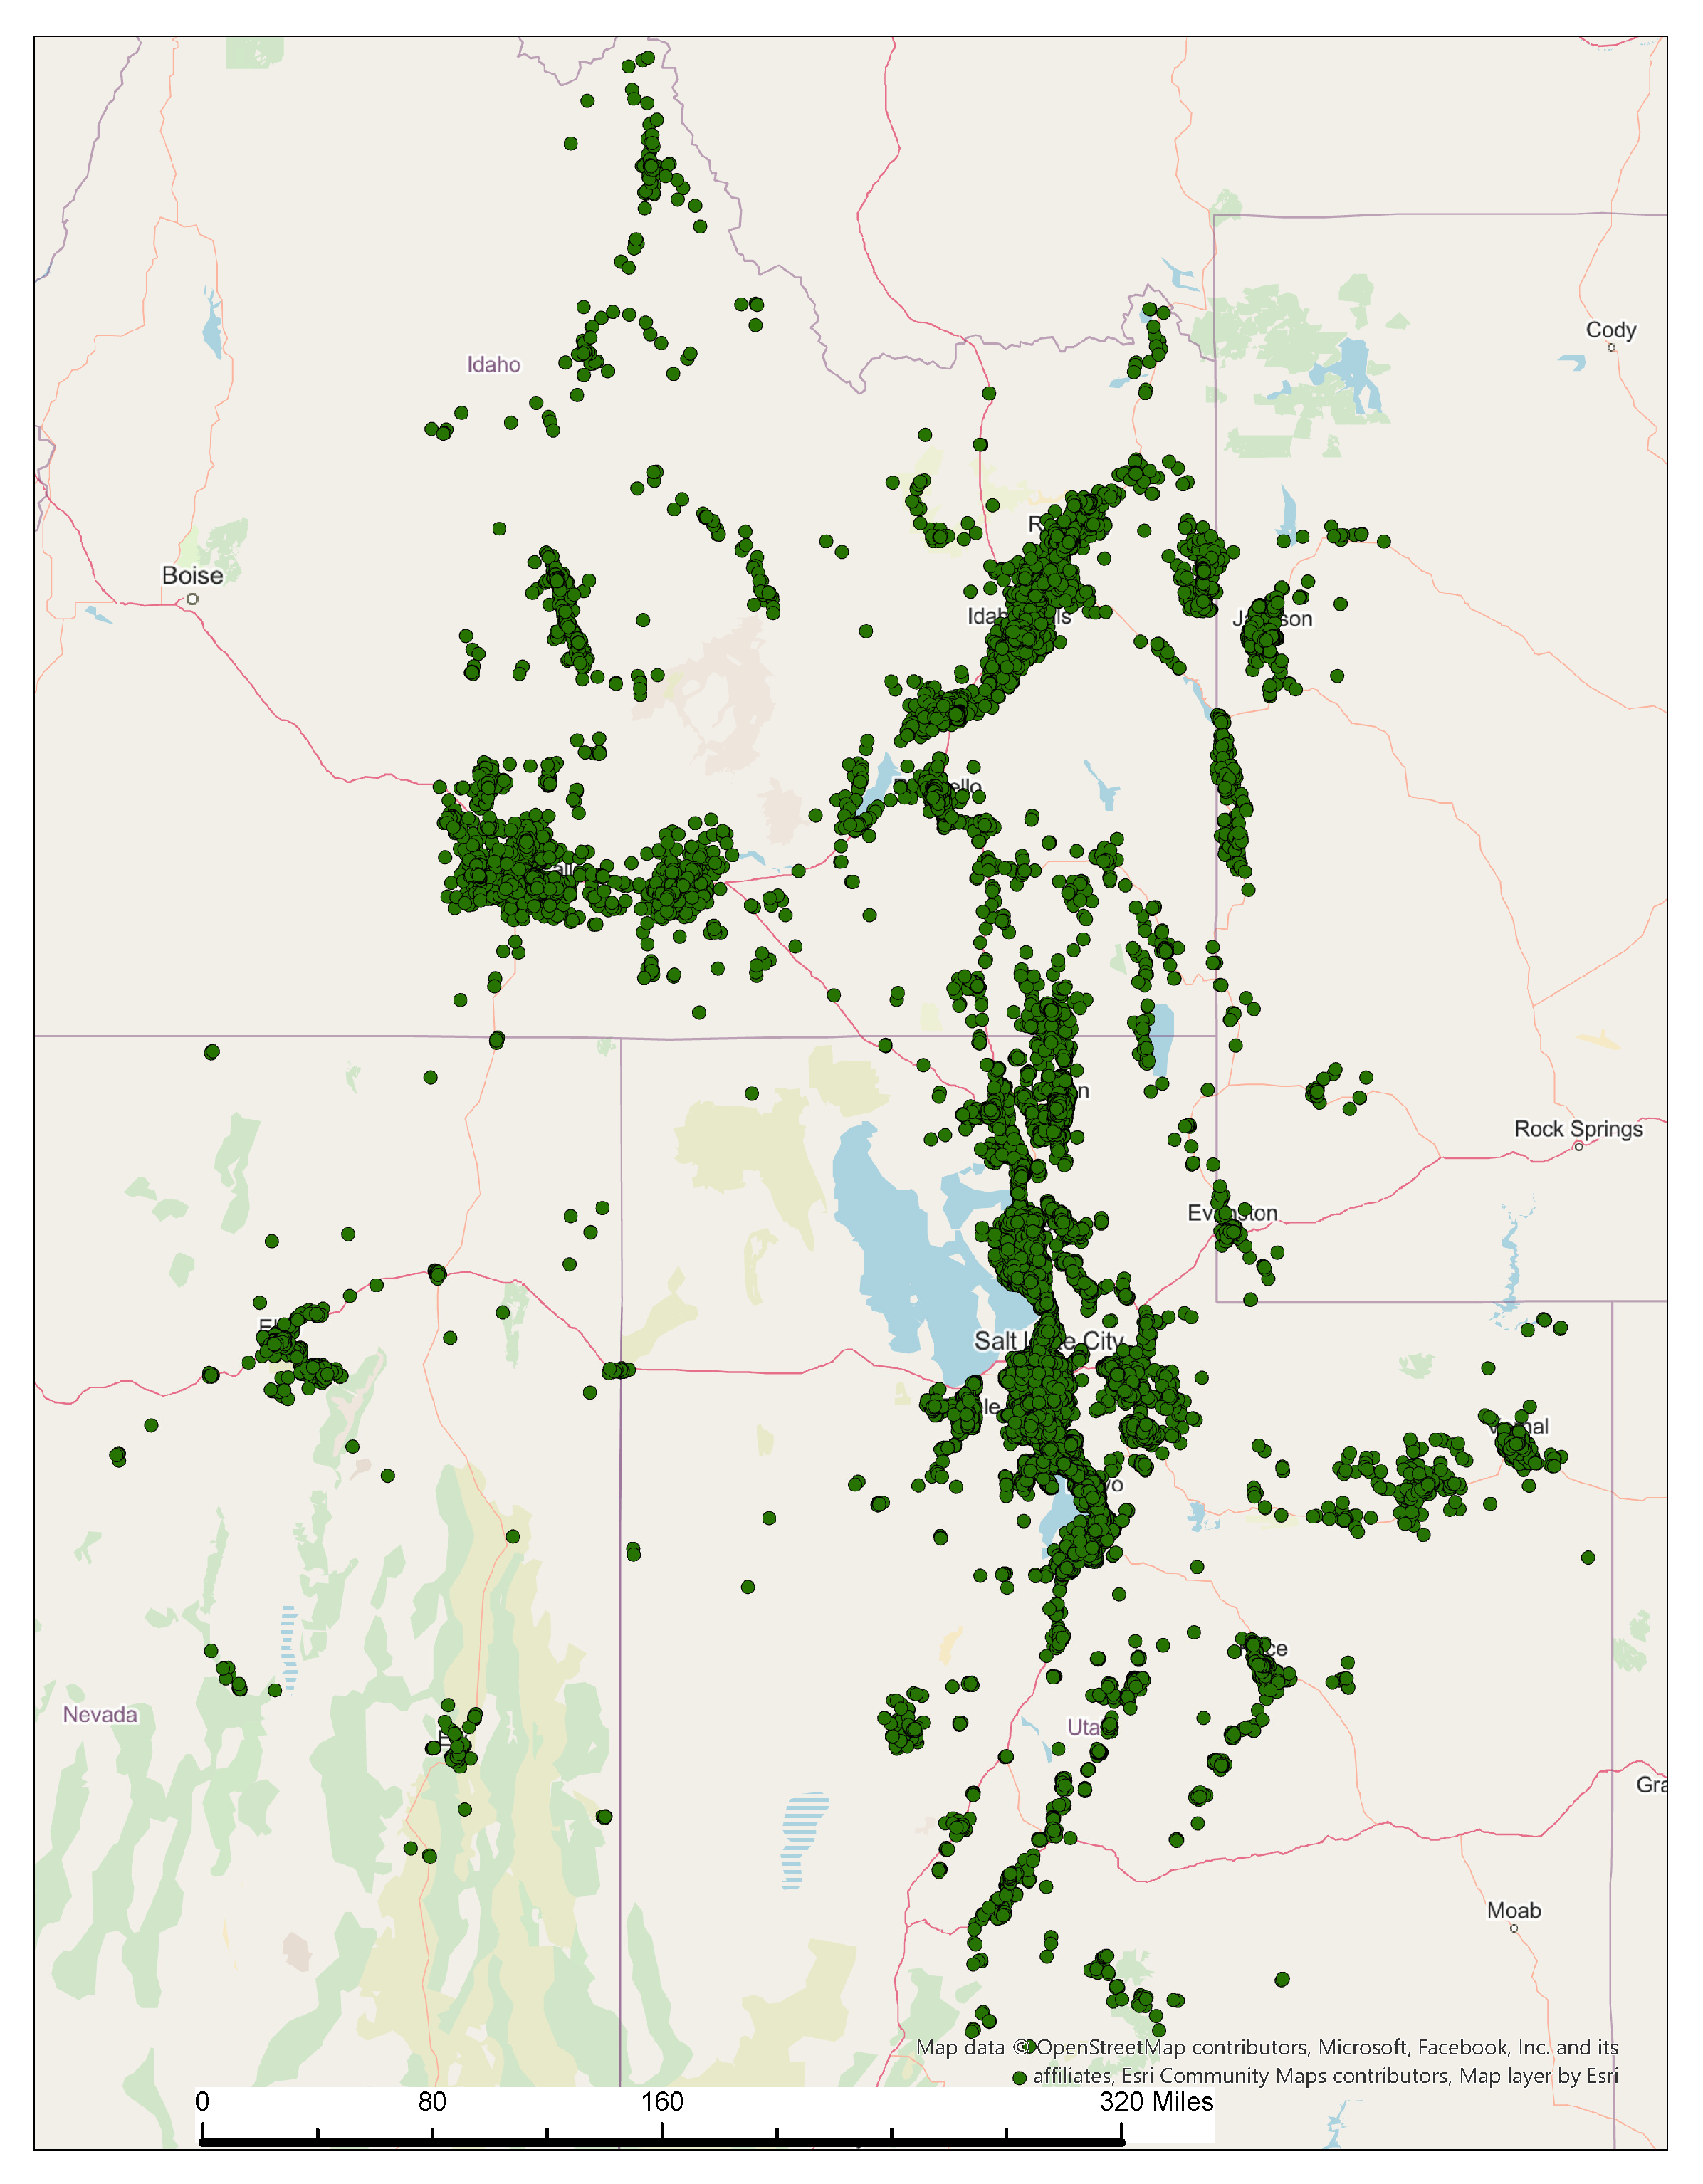
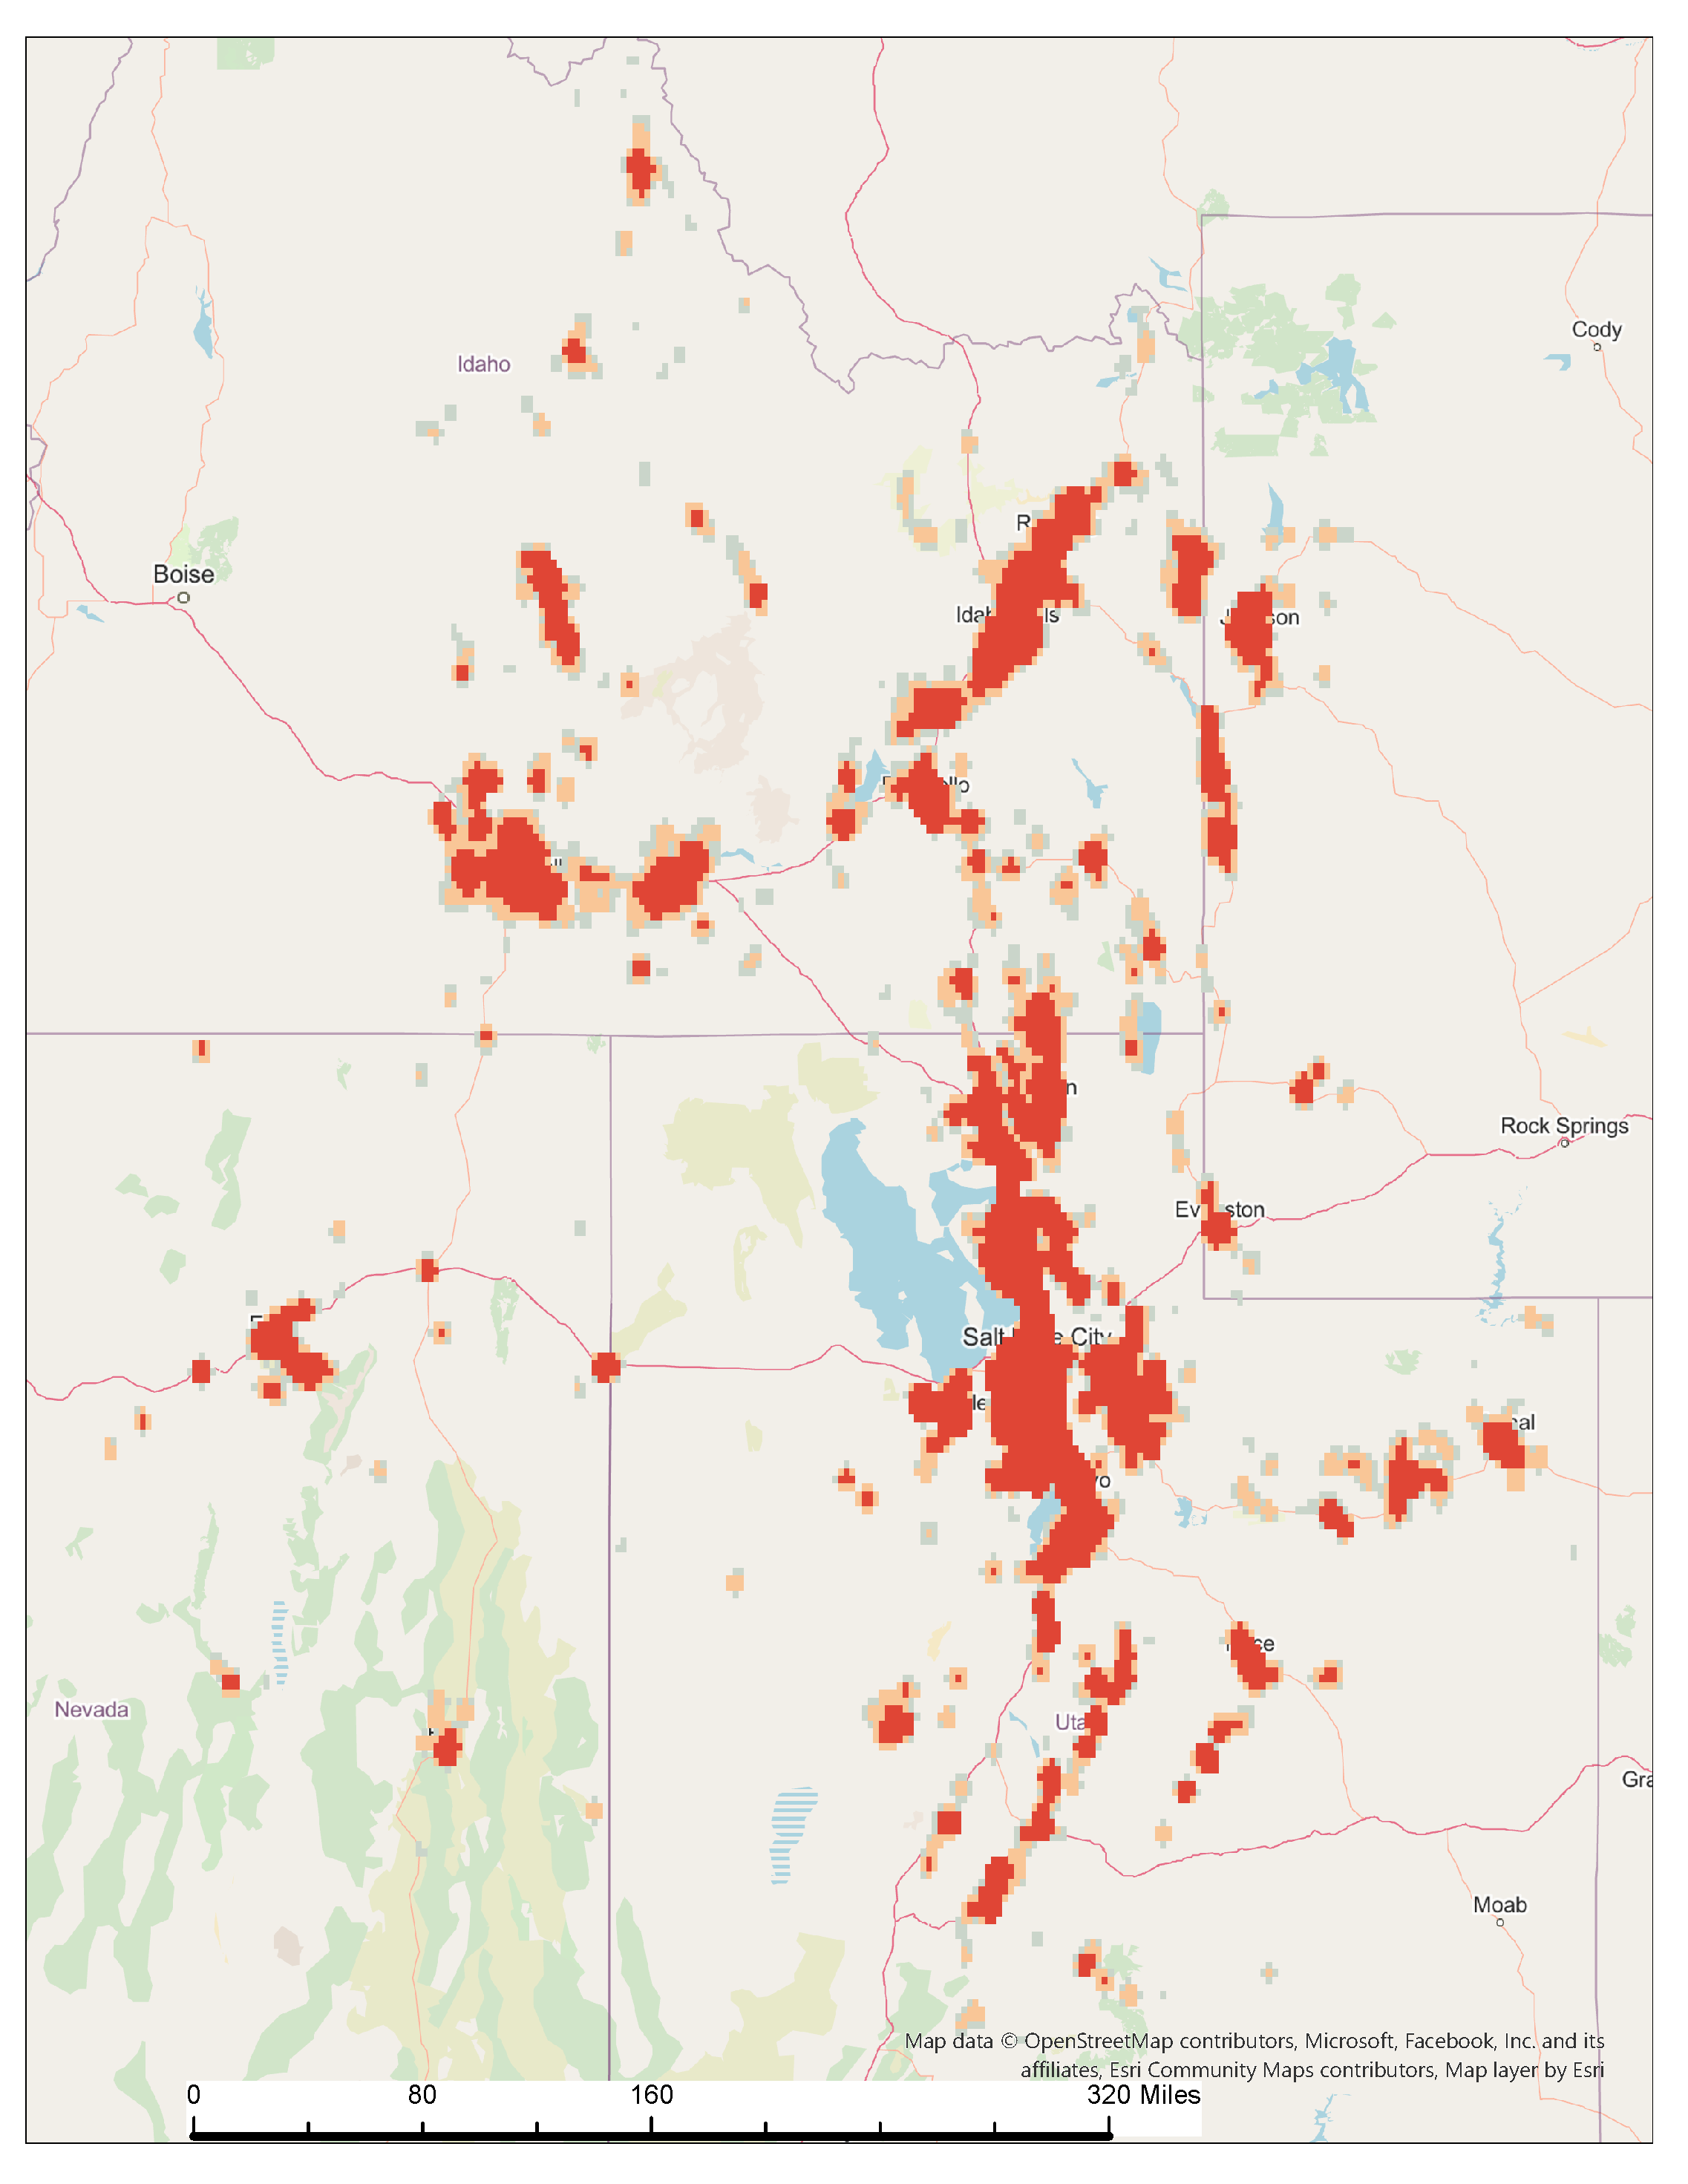
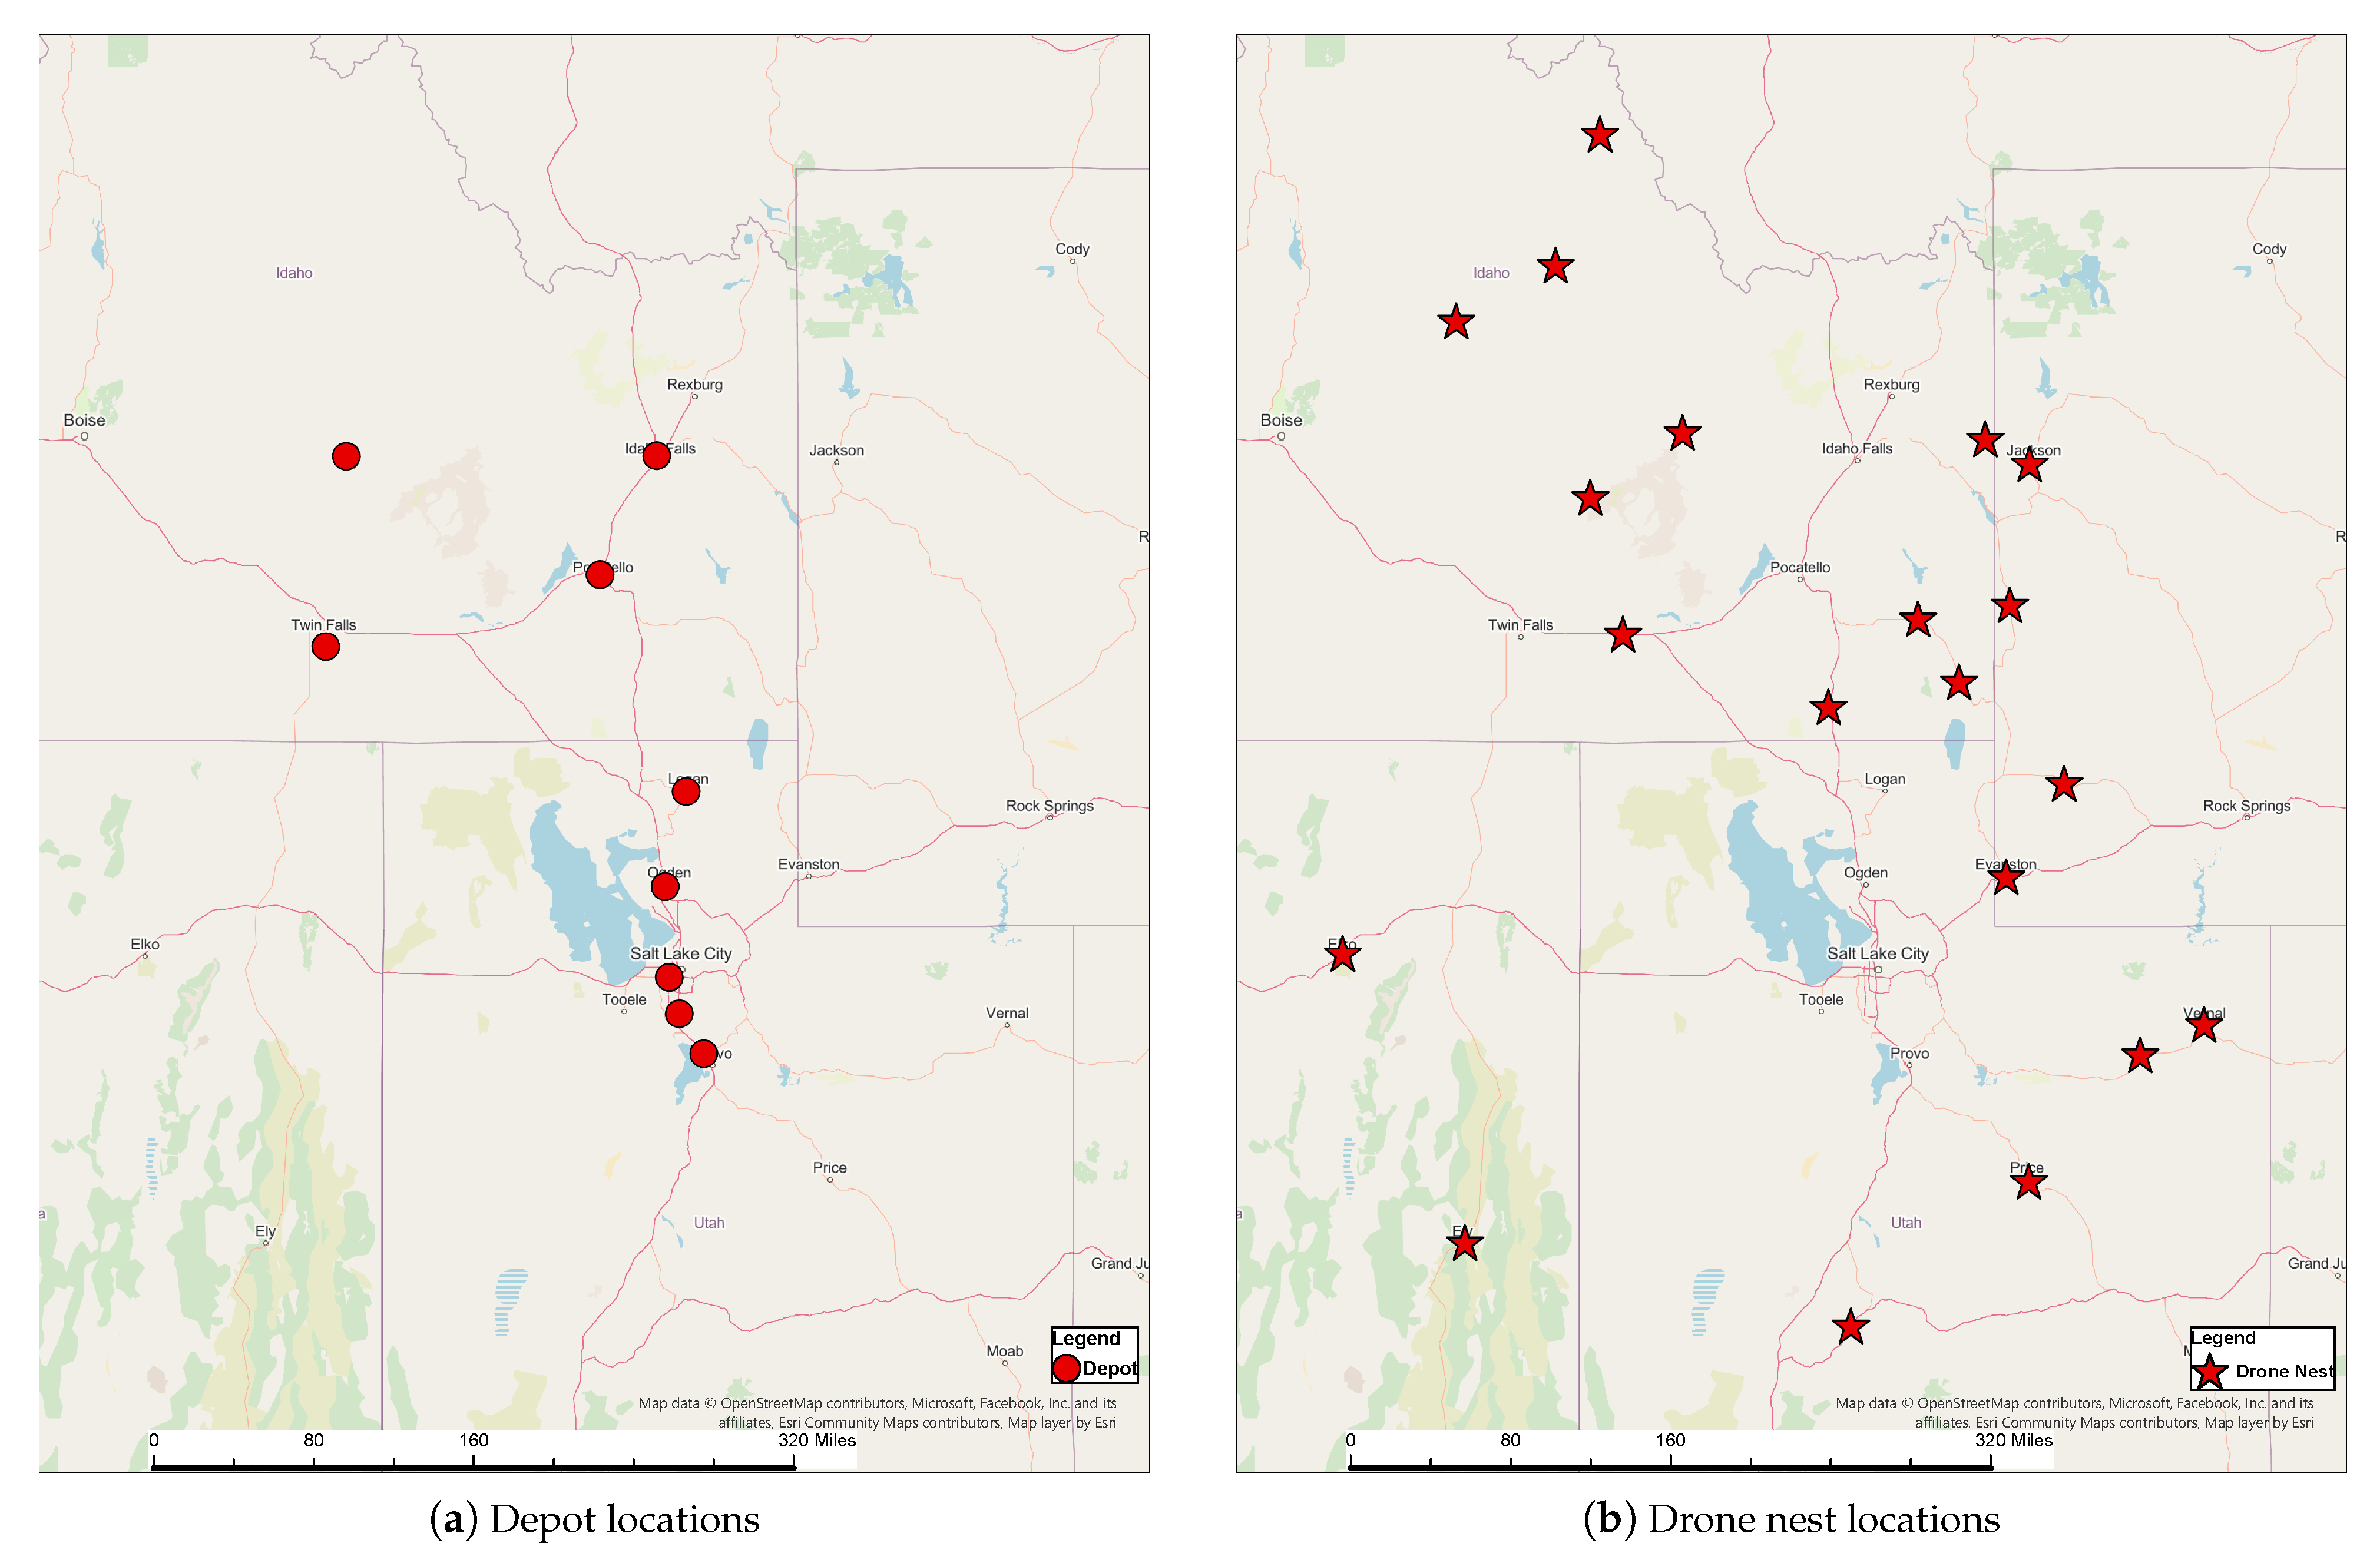
Figure 2 shows the demand distribution of the area across portions of Wyoming, Idaho, Nevada, Utah, and Colorado. To optimize the placement of depots and drone nest locations, geospatial statistical analysis is conducted using ArcGIS Pro. Delivery demand is analyzed through hotspot analysis to identify clusters of high-density addresses. Figure 3 shows the hotspot analysis output in the studied area, with high density with darker red color. Depot locations (Figure 4a) are selected at the most concentrated demand hotspots and serve as fixed starting points for truck routes, marked with red circles in the figure. Drone nest locations (Figure 4b), on the other hand, are strategically chosen in areas with moderate demand density to facilitate deliveries to remote regions and are represented by red stars. The hybrid delivery system operates by assigning trucks to deliver packages within nearby service areas, while drones handle the transfer of packages to intermediate drone nest locations. From these nests, trucks carry out the final delivery to individual addresses. This framework leverages the strengths of drones for reaching remote areas and the capacity of trucks for bulk deliveries within high-density zones. This two-tiered approach ensures comprehensive coverage and efficient routing for both drones and trucks.
Figure 2.
Delivery demand distribution of across remote regions.
Figure 3.
Hotspot analysis of delivery demand across remote regions.
Figure 4.
Map of remote regions showing depot and drone nest locations.
2.3. VRP Solution Algorithm
A customized VRP model is developed and implemented to optimize delivery routes. The VRP model incorporates depots, trucks, and drone nests as key operational components. Trucks begin their routes from depots, deliver to nearby addresses, and return to the depot, while cargo drones transport packages from depots to drone nests. From these nests, trucks complete the final leg of delivery to individual addresses. The VRP model is implemented in ArcGIS Pro using Network Analyst tools to optimize delivery routes. The use of Network Analyst in ArcGIS Pro provides a powerful tool for solving the VRP with customized constraints. Network Analyst allows the integration of spatial data into routing decisions, ensuring that the generated routes consider factors like traffic conditions, vehicle capacity, and road network availability.
A pseudo-code of the VRP Optimization Algorithm is provided in Algorithm 1. This script automates the process of setting up and solving a VRP problem. It begins by importing necessary libraries and setting up the workspace environment. The script then converts CSV data into a spatial feature class, which is essential for spatial analysis. Fields for depot and drone nest location features are calculated to ensure they have the necessary attributes for the VRP analysis. A VRP layer is created with specified parameters, and various locations (orders, depots, drone nests, route template, and break template) are added to this layer. The details information on the orders, route template, and break templates can be found Appendix A Table A1, Table A2 and Table A3, respectively. Finally, the VRP layer is solved to generate optimized routes, facilitating efficient delivery operations that leverage both trucks and drones. This approach enhances delivery efficiency by optimizing routes and integrating multiple delivery modes.
| Algorithm 1: VRP model |
Require: CSV data, geodatabase path, VRP parameters. Ensure: Optimized routes. Initialize: Import necessary libraries (arcpy, os, pandas, datetime). Set workspace and enable overwrite. Convert CSV data to feature class using XYTableToPoint. Calculate fields for depot and drone nest features. Create VRP layer with specified parameters. Add locations for orders, depots, drone nests, routes, and breaks. Solve the VRP layer to generate optimized routes. Output: Optimized routes. |
Enhancing the Algorithm
While the initial VRP model establishes a robust framework for optimizing delivery routes, it exhibits certain limitations that hinder its overall efficiency. The basic model does not fully capture the intricacies of real-world delivery scenarios, such as varying demand densities and the necessity of minimizing travel distances within specific regions. To address these shortcomings and achieve a more optimal solution, we propose an enhancement that incorporates advanced spatial clustering techniques.
To enhance the routing efficiency of the hybrid delivery model, spatial clustering plays a critical role. Spatial clustering groups delivery points geographically, ensuring that deliveries for each vehicle are concentrated within well-defined clusters. This minimizes unnecessary travel and maximizes the operational efficiency of both drones and trucks. The clustering process leverages ArcGIS Pro’s geospatial analytics, where hotspot analysis identifies areas of high demand density. These clusters are then used to assign delivery routes, with vehicles serving spatially coherent regions. The clustering objective minimizes the total intra-cluster distance, expressed as:
where is the cost (e.g., distance) of assigning order i to route j, and is a binary variable indicating whether order i is assigned to route j.
This spatial clustering approach ensures that delivery routes remain geographically compact, reducing travel distances and improving overall route efficiency.
Key customizations in the VRP model include the following:
- The VRP layer is configured to group delivery orders geographically using Python scripting and ArcGIS Pro. This reduces route overlap and keeps delivery points within each cluster spatially proximate.
- Route zones are defined to assign specific geographic regions to vehicles, further minimizing overlap and ensuring balanced workload distribution.
- Tasks requiring coordinated pickup and drop-off are grouped into order pairs, optimizing routes and minimizing unnecessary detours.
By implementing spatial clustering as part of the VRP layer, this study contributes to the logistics field by demonstrating how geographic grouping can significantly enhance delivery efficiency in hybrid truck-and-drone models. This customization ensures that both drones and trucks operate in a manner that maximizes efficiency while meeting the unique logistical challenges of remote areas.
The solution approach in Network Analyst is customized using Python scripting to automate the VRP model and implement the specific adjustments for the hybrid system. The integration of spatial clustering and route zones enables us to tailor the delivery system to the specific geography of remote areas. By prioritizing the grouping of deliveries within spatially coherent areas, the model reduces the risk of vehicles traveling long distances unnecessarily, ensuring more efficient use of trucks. Furthermore, order pairs provide a mechanism to optimize delivery schedules, ensuring that tasks requiring coordinated pickup and drop-off are handled effectively. To improve route efficiency, the model includes customizations such as spatial clustering, route zones, and order pairs. This model incorporates the operational structure of depots, trucks, and drone nests. Trucks start their routes from depots or drone nests, deliver packages to nearby addresses, and return to the depot or drone nests, while cargo drones transfer packages from depots to drone nests. From these nests, trucks continue to deliver packages to the final addresses. Python scripting is employed to automate data preprocessing, route generation, and the enforcement of constraints. Python also supports advanced customizations by creating dynamic rules for route optimization based on specific geographic or operational needs. These customizations prioritize clustering delivery orders within specific service areas to reduce travel distances and enhance operational efficiency.
Two scenarios are analyzed to evaluate the effectiveness of the hybrid model. The base case considers truck-only delivery, where trucks deliver directly from depots to all addresses without drone assistance. The hybrid model, on the other hand, incorporates cargo drones to transfer packages to remote areas (i.e., drone nests). Trucks complete the final leg of delivery for these remote areas, while also handling deliveries to addresses in close proximity to the depots without drone assistance. Only the farther remote portions utilize drone assistance. A comparative analysis between these scenarios is conducted using metrics such as total delivery time, distance traveled, and the number of delivery routes required. A pseudo-code of the Hybrid Truck-and-Drone Delivery Optimization Algorithm is provided in Algorithm 2.
| Algorithm 2: Hybrid Truck-and-Drone Delivery Optimization Algorithm |
Require: order data, route template, break template, drone specifications (range, payload), truck parameters, road network data. Ensure: Optimized routes, depot locations, drone nest locations, and performance metrics. Initialize: (*Set of orders*) (*Set of delivery routes*) Generate candidate drone nest locations using geospatial statistical analysis. Assign initial routes for trucks using VRP algorithm. Phase 1: Optimize Truck-and-Drone Hybrid Model while (performance improvement threshold not met) do Solve VRP to optimize truck routes with drone nests. Assign delivery tasks to drones and trucks based on proximity and capacity. Update based on optimized routes. If significant improvement in observed: Retain current and . Else: Modify drone nest locations based on hotspot analysis. end while Phase 2: Apply Spatial Clustering for Route Refinement Group delivery points into clusters based on geographical proximity. Re-optimize VRP within each cluster. Update with improved on-road minutes and total miles. Phase 3: Enhance Drone Operational Capabilities Upgrade drone range and payload capacity. Recalculate required drone nests and revise drone-truck allocations. Optimize routes using updated drone parameters. Update to reflect changes in routes, minutes, and miles. Output: Optimized , , and final . |
We now make the following assumptions to simplify our modeling approach:
Assumption 1.
Every day, on average, 15% and 3% of the addresses in the study area will have delivery and pickup, respectively.
Assumption 2.
Depot locations are permanent, fixed points where delivery trucks will begin and end their routes.
Assumption 3.
Delivery trucks start from the depot, deliver to nearby addresses, and return to the same depot after completing their deliveries.
Assumption 4.
Cargo drones fly from depots to the nearest drone nest locations to transfer packages. These drones can carry bulk packages together.
Assumption 5.
Drone nest locations are temporary hubs that facilitate deliveries to remote areas and are strategically selected based on demand density.
Assumption 6.
For the hybrid model, delivery trucks will operate from both depots and drone nest locations to cover all assigned addresses.
Assumption 7.
The performance comparison between truck-only and hybrid delivery models is based on delivery time, travel distance, and route efficiency.
To strengthen the empirical foundation of these assumptions, sensitivity tests were performed by varying key operational parameters such as delivery density, drone range, and payload capacity. As detailed in Section 3.2, these variations produced consistent improvements in delivery time and mileage, indicating that the model’s conclusions are robust under realistic changes in assumptions.
3. Computational Study and Managerial Insights
In order to test the performance of the solution approach and methodology proposed in Section 2 and to draw managerial insights, we develop a case study using the area across portions of Wyoming, Idaho, Nevada, Utah, and Colorado as a testing ground for the analysis. In this section, we first provide the details about the input parameters used to develop the case study. Next, we discuss the results obtained from the experimental study and then present the computational performance of the hybrid delivery system.
3.1. Input Parameters
To conduct the analysis, various data sources were integrated and prepared for geospatial analysis and VRP modeling. Road network data were sourced from ArcGIS Online to provide a detailed representation of the regional road network, including attributes such as road type, speed limits, and connectivity [35]. Demand points were derived from parcel delivery data and census block group information [36,37]. Delivery and pickup were estimated through a spatial join of parcel data and population data to determine demand density and distribution across the study area as shown in Appendix A Table A1. Operational parameters, including truck and drone capacities, flight ranges, fuel consumption, and time constraints, were also included to simulate realistic delivery scenarios [38,39].
The hybrid delivery model was implemented using Python 3.11.8 (arcpy library) and ArcGIS Pro 3.3.1 [40], executed on a desktop computer with a 14th Gen Intel Core i9-14900K processor (24 cores, 32 threads, 3.2 GHz to 5.6 GHz), 64.0 GB of RAM, and an NVIDIA GeForce RTX 4070Ti SUPER 16 GB GDDR6X Graphics card. Data preprocessing, including spatial clustering, hotspot analysis, and identification of suitable depot and drone nest locations, was performed using ArcGIS Pro 3.3.1. The Network Analyst extension was utilized to conduct VRP modeling, with Python scripting automating critical processes such as data preparation, route optimization, and constraint enforcement. Customizations to the VRP model included spatial clustering, route zoning, and order pairing to optimize route efficiency and ensure robust performance. This computational setup was essential to address the spatial and operational complexities of the selected regions effectively. Although each regional problem in this study was solved efficiently with the available computational setup, optimizing all depots or much larger networks simultaneously would require increased computing resources, such as parallel processing or cloud platforms. As the problem size grows, both memory usage and runtime can become bottlenecks due to the NP-hard nature of vehicle routing problems.
3.2. Experimental Results
This section evaluates the hybrid truck-and-drone delivery model’s performance across regions within Wyoming, Idaho, Nevada, Utah, and Colorado. These areas present significant logistical challenges, including low population density, rugged terrain, and inadequate infrastructure, making them ideal testbeds for the proposed delivery solutions. The results highlight the operational improvements achieved through the integration of drones, further optimization via spatial clustering, and enhancements to drone capabilities. By addressing these region-specific challenges, the study demonstrates the potential for scalable solutions to enhance last-mile delivery efficiency and sustainability in complex geographical environments.
3.2.1. Comparative Analysis of Delivery Models
To evaluate the effectiveness of the proposed hybrid truck-and-drone delivery model, a comparative analysis was conducted against a traditional truck-only model. In this section, we present a detailed comparative analysis of delivery performance metrics between truck-only and hybrid truck-and-drone delivery models. The analysis highlights the operational improvements achieved through the integration of drones, demonstrating the potential for enhanced efficiency in last-mile delivery logistics. The comparative analysis of delivery performance metrics for truck-only versus truck-and-drone systems demonstrates significant operational improvements with the hybrid model. Detailed metrics are summarized in Table 2. For the truck-only model, the system required 303 routes, with 125,999.66 on-road minutes and a total of 37,487.24 miles traveled for the study area. The hybrid truck-and-drone model, in contrast, achieved significant reductions: 271 routes (10.6% reduction), 107,003.45 on-road minutes (15% reduction), and 26,987.59 total miles (28% reduction). These findings underline the impact of integrating drones in reducing logistical inefficiencies in last-mile deliveries. Throughout our study, drone travel times and distances were minimal relative to truck operations and did not significantly impact overall delivery metrics; therefore, they were not included in the reported results.
Table 2.
Comparison of results from the base case and hybrid scenario by region.
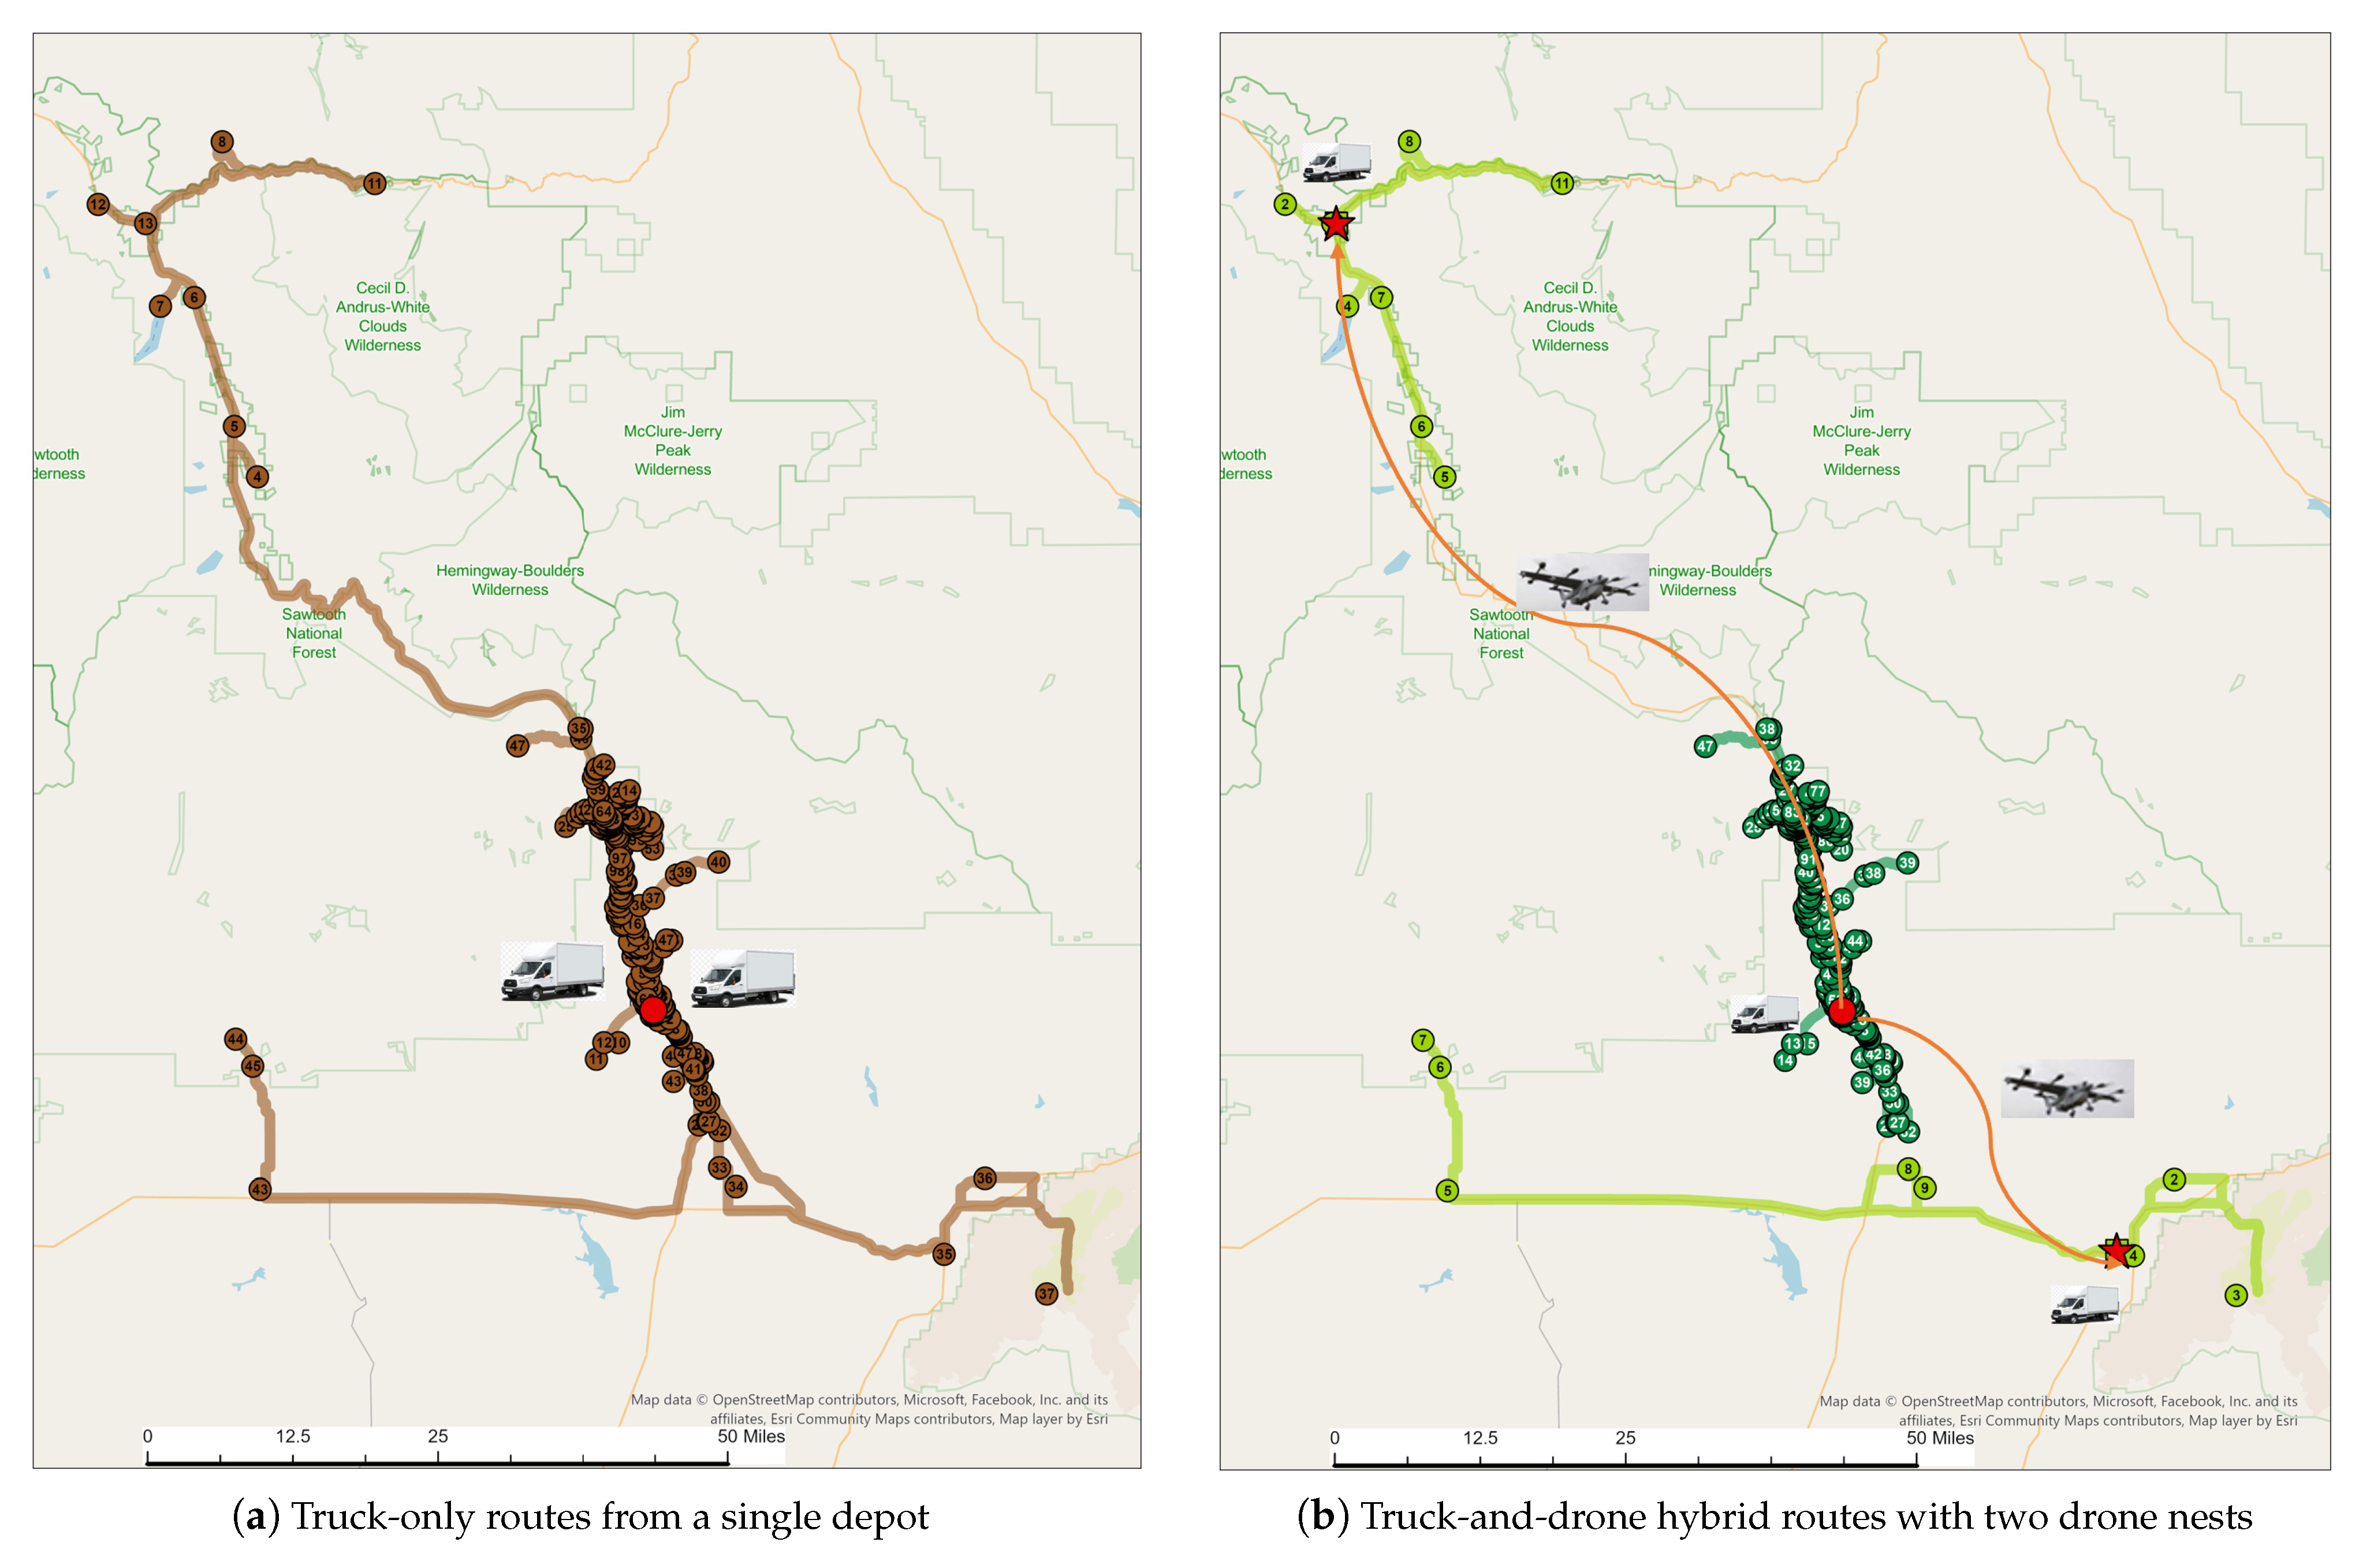
In addition to numerical results, visualizations of VRP outputs enhance understanding of the improvements. The truck-only VRP output is shown in Figure 5a, depicting the delivery routes originating from a single depot. In the figure, the red circle represents the depot location where the trucks begin their deliveries, while all the brown circles represent the delivery addresses. The lines connecting the circles indicate the truck routes, and the numbers on the brown circles represent the sequence of deliveries based on the VRP output. In comparison, the hybrid truck-and-drone VRP output is illustrated in Figure 5b, showing optimized routes for trucks and the inclusion of two drone nests serving the same depot. Here again, the red circle represents the depot location, which serves as the starting point for delivery trucks addressing nearby areas. In the figure, dark green circles represent the delivery addresses, with numbers indicating the sequence of deliveries, while dark green lines illustrate the truck routes originating from the depot.
Figure 5.
VRP output for truck-and-drone hybrid routes at a single depot.
For areas farther from the depot, deliveries are supported by cargo drones. From the depot, these drones carry bulk packages to the two designated drone nest locations shown in the figure. Once the packages arrive at the drone nests, trucks are responsible for delivering them to individual addresses. In the figure, light green circles represent these individual delivery addresses, with numbers denoting the delivery sequence, while light green lines indicate the truck routes from the drone nests.
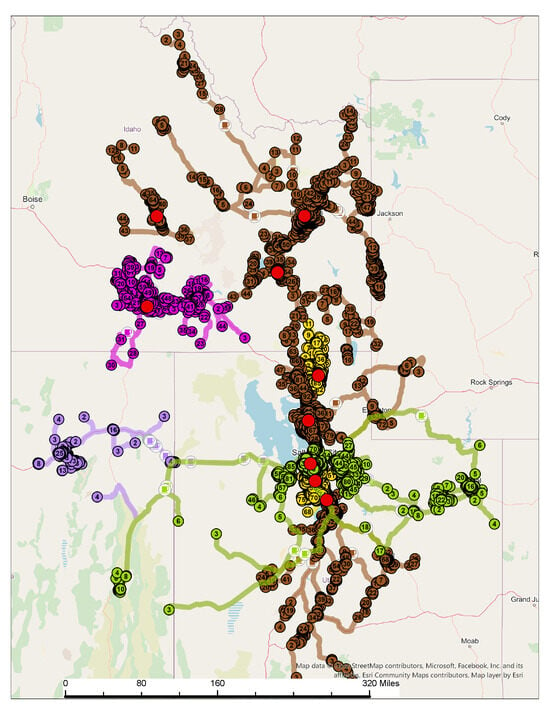
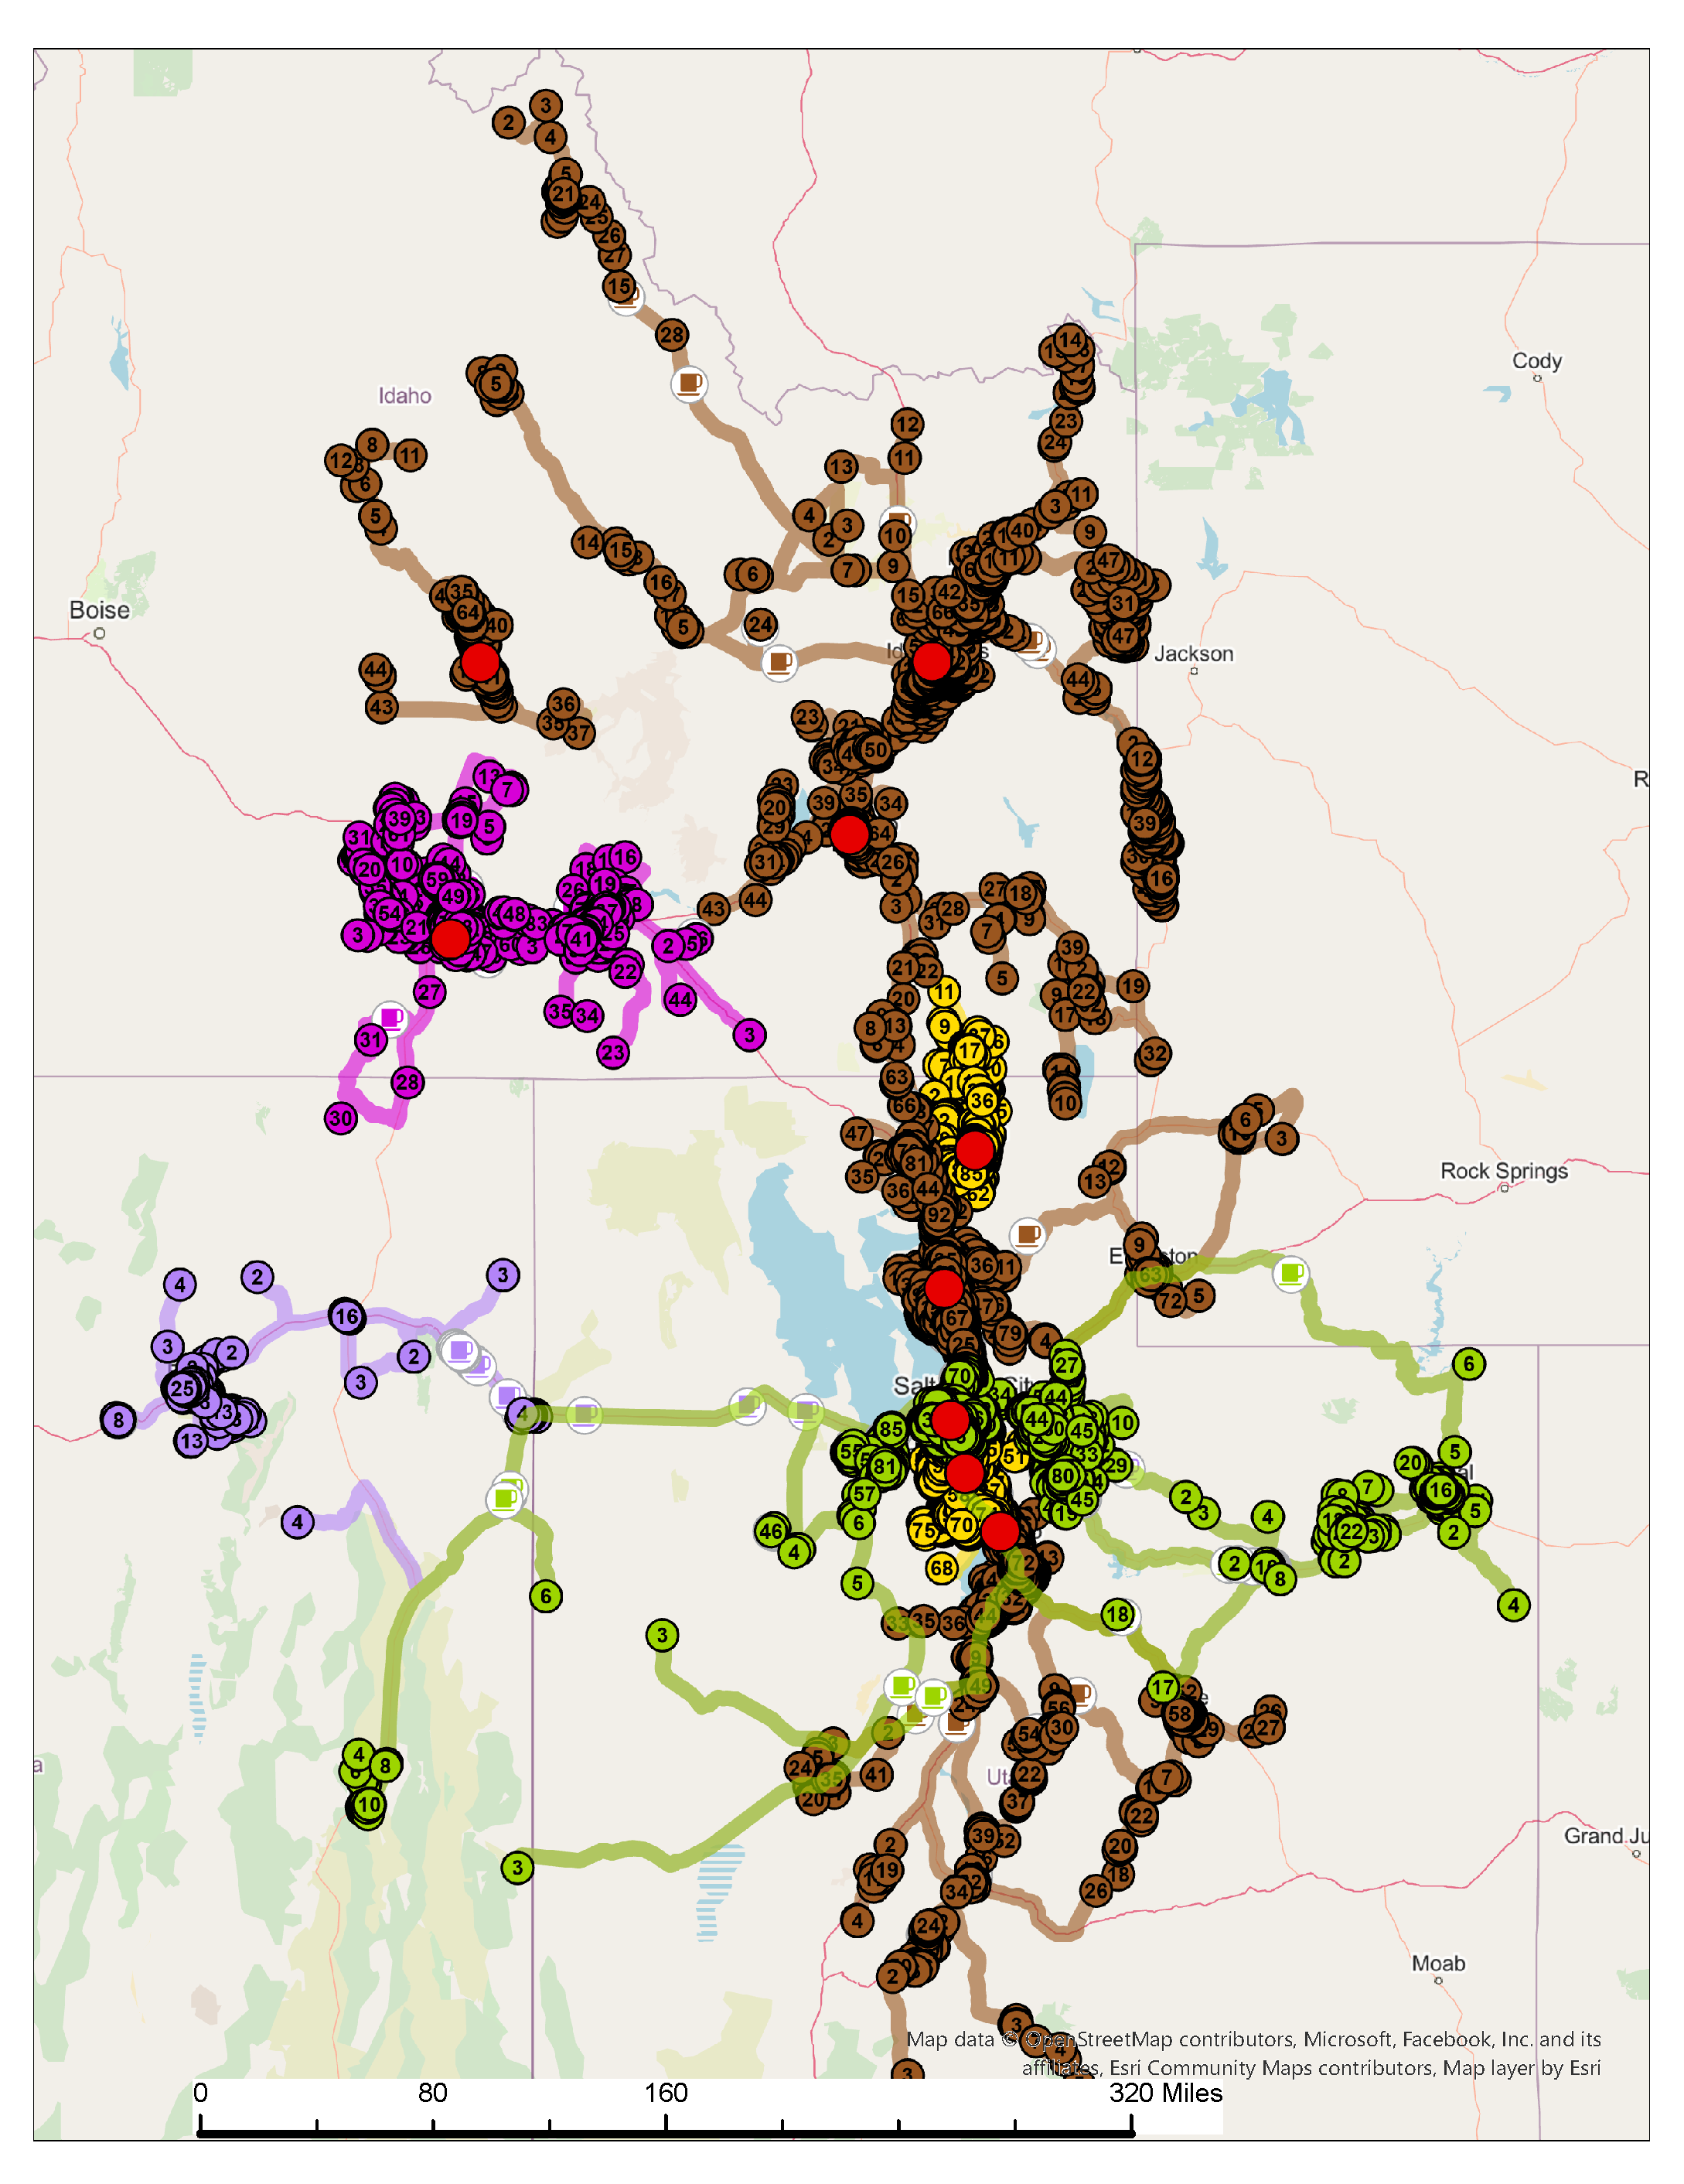
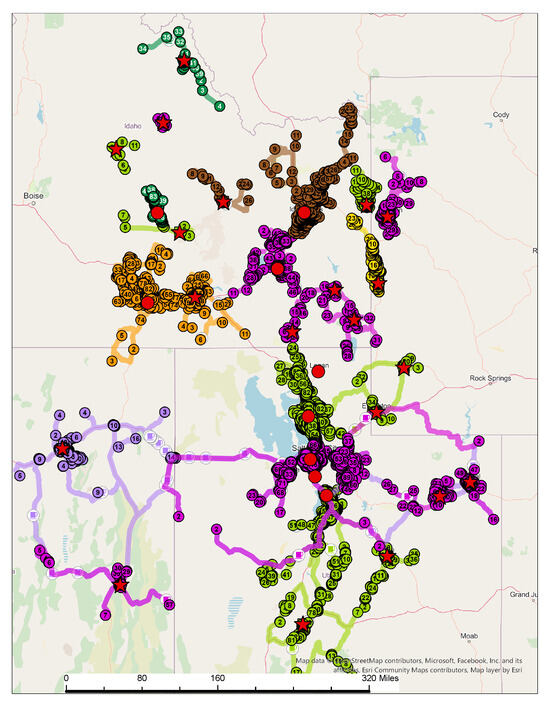
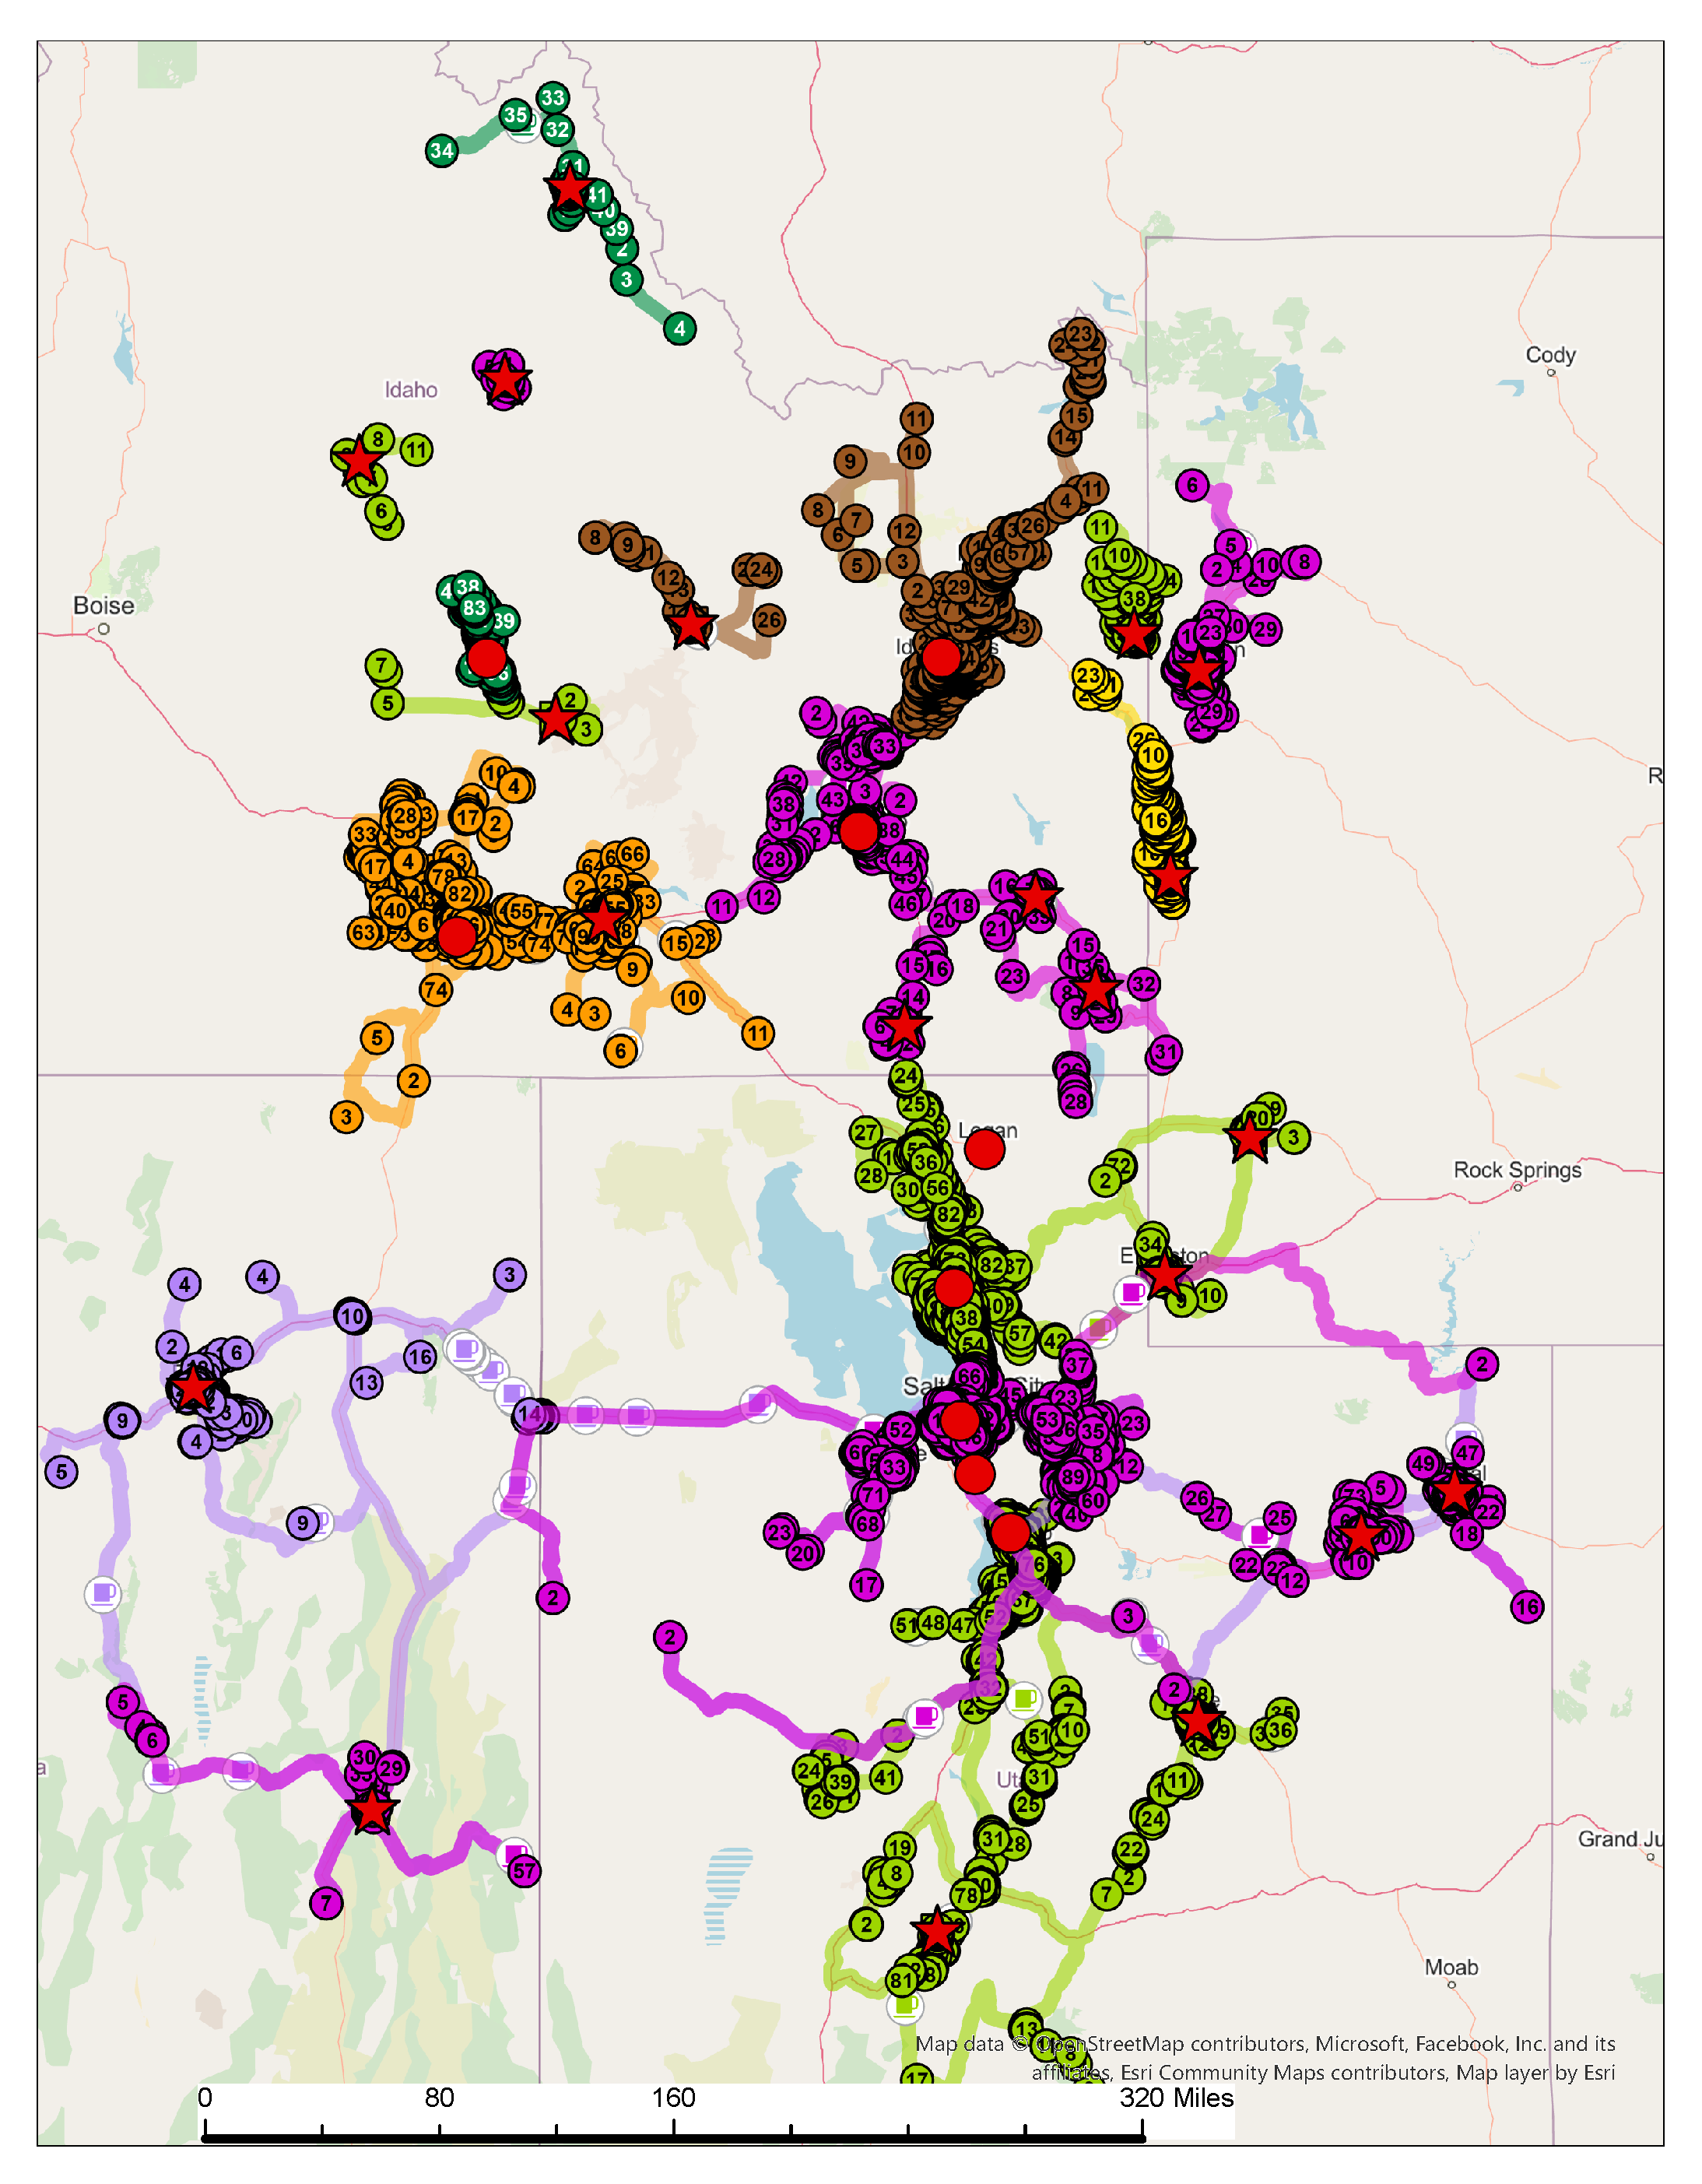
At a broader scale, the VRP outputs for all nine depots are presented in Figure 6, while the optimized hybrid model with 20 drone nests is shown in Figure 7. The reduction in route overlap and overall mileage is visually evident in these maps. The integration of drones not only improved delivery metrics but also addressed logistical challenges associated with remote areas. The incorporation of drone nests enabled direct delivery to locations that would otherwise have required extended truck travel, reducing both fuel consumption and delivery time. The maps reinforce these findings, showcasing streamlined routing and reduced redundancies in the hybrid model.
Figure 6.
VRP output for truck-only routes across nine depots.
Figure 7.
VRP output for truck-and-drone hybrid routes with twenty drone nests and nine depots.
3.2.2. Impact of Spatial Clustering on System Performance
In addition to the initial benefits observed with the hybrid truck-and-drone delivery model, further enhancements were explored through the application of spatial clustering techniques. This section details the additional optimizations achieved by refining the VRP algorithm to improve delivery efficiency. While the initial implementation of the hybrid truck-and-drone system was effective, further optimization was achieved through the application of spatial clustering techniques. By customizing the VRP algorithm to assign geographically close orders to individual vehicles, delivery efficiency improved significantly. The results of this refinement are summarized in Table 3.
Table 3.
Enhanced metrics with spatial clustering comparison of the results obtained from the base case and after scenario by region.
The hybrid model initially achieved 107,003.45 on-road minutes and 26,987.59 total miles. With spatial clustering enabled, these metrics improved to 105,529.04 on-road minutes and 26,714.63 total miles, representing an additional 1.4% reduction in on-road minutes and a 1% reduction in total miles. These improvements, though incremental, underscore the effectiveness of clustering in maintaining compact delivery zones and minimizing unnecessary travel.
The spatial clustering approach ensures that vehicles operate within well-defined service areas, reducing travel distance and optimizing load distribution. This refinement is particularly important in scenarios with high delivery density or complex service regions, as it prevents route overlap and enhances operational predictability and reveal more compact and organized routes in the clustered model. This demonstrates how spatial clustering can enhance the hybrid model’s capability to tackle the challenges of last-mile delivery, offering further reductions in operational costs and environmental impact.
3.2.3. Impact of Enhanced Drone Capacity on Delivery Efficiency
Building upon the previous enhancements, further optimization was explored by increasing the drone’s operational capabilities. By upgrading the drone’s mission range from 300 miles to 500 miles and its payload capacity from 300 lbs to 500 lbs, the hybrid system achieved even greater efficiency. This upgrade allowed for the reduction of drone nest locations from 20 to 10, which had significant effects on delivery performance.
The increased mission range and payload capacity enabled drones to handle longer distances and heavier loads, thereby reducing the need for frequent drone nest stops. With fewer drone nests, the delivery system was able to consolidate routes, reduce overlap, and improve overall spatial efficiency. This change also allowed for a better distribution of trucks and drones across the remaining nests, further improving the system’s performance. The results of this modification are summarized in Table 4, highlighting significant reductions in delivery metrics. The total number of routes decreased from 271 in the initial hybrid model to 259, representing a 4.4% decrease. On-road minutes were reduced from 107,003.45 min to 102,178.74 min, a 4.5% reduction. Additionally, the total mileage dropped from 26,987.59 miles to 25,659.41 miles, reflecting a 4.9% reduction.
Table 4.
Impact of enhanced drone capacity on delivery performance.
This enhancement mirrors ongoing developments in drone technology, such as the efforts by Elroy Air. Their current Chaparral drone offers a mission range of 300 miles and a payload capacity of 300 lbs, making it a capable solution for regional cargo delivery. However, Elroy Air is actively working to improve these figures, aiming to increase the range to 500 miles and the payload capacity to 500 lbs. These improvements could further revolutionize logistics by reducing the number of drone nests needed and streamlining last-mile delivery in remote areas, much like the results seen in this study.
With the increased range and payload capacity of drones, the optimized system now covers more ground with fewer drone nest locations, effectively decreasing the need for overlapping routes and further optimizing the use of both drones and trucks. The reduction in operational costs and environmental impact is also significant, as fewer drone nests and reduced mileage lead to lower fuel consumption and fewer emissions. These findings emphasize the potential of increasing drone capacities to enhance the hybrid delivery model, offering a scalable solution for remote and rural delivery challenges.
4. Significance of Findings and Implications
Our study demonstrates the pioneering potential of hybrid truck-and-drone delivery systems, particularly in regions with limited infrastructure and challenging terrain. Compared to traditional truck-only models, our proposed system showed remarkable improvements, such as fewer routes, less time on the road, and reduced total miles traveled. These changes lead to lower operational costs, a smaller environmental footprint, and better service levels, marking a significant step toward more sustainable last-mile logistics.
By integrating spatial clustering, we further enhanced these benefits, demonstrating the power of data-driven optimization in refining delivery operations. Keeping delivery zones compact and minimizing route overlap boosts the predictability and efficiency of logistics networks. This underscores the importance of using advanced geospatial statistical analysis and optimization algorithms in logistics planning, paving the way for more robust and scalable delivery systems. Improvements in drone capabilities, like increased range and payload, also show how technological innovation can reshape logistics. Reducing the number of drone nests and overlapping routes streamlines operations and proves the scalability of hybrid delivery systems for wider use. This has major implications for supply chain management, especially in rural and remote areas where traditional methods often fall short.
From a managerial standpoint, our study offers practical insights into deploying hybrid delivery models. Logistics managers can use these findings to make informed decisions about resource allocation, route planning, and technology investments, ultimately driving greater efficiency and sustainability. Policymakers and industry stakeholders can also leverage this research to push for regulatory frameworks that support the integration of drones into existing logistics networks. Beyond operational improvements, the environmental benefits of the hybrid model are significant. By cutting down on mileage and fuel consumption, the system helps lower greenhouse gas emissions, aligning with global sustainability goals. These findings resonate with broader environmental conservation efforts and carbon footprint reduction, highlighting the role of innovative logistics solutions in promoting sustainable development.
Despite its promising findings, this study has several limitations. It focuses mainly on specific remote regions with particular infrastructure and regulatory contexts. Adapting the model to different settings with varying regulatory frameworks, infrastructure levels, or operational constraints will require further modifications that incorporate local legal requirements, technological readiness, and logistical variability.
Furthermore, technology adoption barriers remain a significant challenge. High implementation costs, regulatory uncertainties, lack of standardization, infrastructure gaps, and stakeholder resistance can impede widespread deployment. Addressing these barriers demands comprehensive policy frameworks encompassing clear regulatory pathways, financial incentives, cross-sector collaborations, and community engagement. Public-private partnerships and workforce training will be critical for technology diffusion and sustainable integration.
Future research should explore robust and adaptive modeling techniques that accommodate stochastic environments and dynamic constraints, extend empirical validation across varied geographies, and incorporate multi-modal logistics. Additionally, detailed cost-effectiveness and environmental impact analyses, combined with policy-focused studies, will help realize the full potential of hybrid truck-and-drone delivery systems.
5. Conclusions
This study introduces a novel hybrid delivery system that integrates drones and trucks to optimize logistics in remote areas. By leveraging geospatial statistical analysis, we identified optimal depot and drone nest locations, which significantly enhanced the efficiency of last-mile delivery operations. Our customized VRP model demonstrated notable improvements over traditional truck-only delivery systems, achieving a 10.5% reduction in routes, a 15% decrease in on-road minutes, and a 28% reduction in total miles traveled. Further enhancements through spatial clustering provided additional gains, with on-road minutes and total miles reduced by 1.4% and 1%, respectively. These findings underscore the transformative potential of hybrid delivery systems in addressing logistical challenges in regions with sparse infrastructure.
Expanding the drone’s operational capacity from 300 miles and 300 lbs to 500 miles and 500 lbs further amplified these benefits. With enhanced drone capabilities, the system required fewer drone nests, leading to a 4.4% reduction in routes, a 4.5% decrease in on-road minutes, and a 4.9% reduction in total miles. This improvement highlights the role of technological advancements in boosting the scalability and efficiency of hybrid logistics solutions.
While the proposed hybrid delivery framework demonstrates substantial advancements, several areas warrant further investigation. Real-time demand forecasting could enhance system responsiveness by enabling dynamic adjustments to delivery schedules. Addressing drone-specific challenges, such as battery efficiency, weather resilience, and regulatory compliance, is critical for reliable operations. Additionally, consideration of cost-effectiveness alongside evolving regulatory frameworks is essential for the practical adoption of hybrid delivery systems. Expanding the hybrid model to incorporate multi-modal logistics, like rail or autonomous vehicles, could enhance adaptability to diverse logistical needs.
Environmental impact analysis, particularly regarding greenhouse gas reductions, would provide a fuller picture of the model’s sustainability. Extending this approach to urban environments with dense delivery demands could reveal new opportunities and constraints. Further exploration of emerging drone technologies and larger payload capacities could significantly optimize delivery efficiency. Lastly, a detailed cost-effectiveness analysis is essential to evaluate the trade-offs between initial investments and long-term savings, offering insights into the economic scalability of these systems.
Author Contributions
Conceptualization, M.A.Q.; methodology, M.A.Q.; software, M.A.Q.; validation, M.A.Q., M.F.R. and M.M.B.; formal analysis, M.A.Q.; investigation, M.A.Q.; resources, M.A.Q.; data curation, M.A.Q.; writing—original draft preparation, M.A.Q.; writing—review and editing, M.F.R. and M.M.B.; visualization, M.A.Q.; supervision, M.A.Q.; project administration, M.A.Q. All authors have read and agreed to the published version of the manuscript.
Funding
This research received no external funding.
Institutional Review Board Statement
Not applicable.
Informed Consent Statement
Not applicable.
Data Availability Statement
The original contributions presented in this study are included in the article. Further inquiries can be directed to the corresponding author.
Conflicts of Interest
The authors declare no conflicts of interest.
Appendix A
Table A1.
Summary of Orders for VRP.
Table A2.
Summary of Route Template for VRP.
Table A3.
Summary of Break Template for VRP.
References
- Quek, S.G.; Selvachandran, G.; Sham, R.; Siau, C.S.; Ramli, M.H.M.; Ahmad, N. A fuzzy logic based optimal network system for the delivery of medical goods via drones and land transport in remote areas. In International Conference on Intelligent Systems Design and Applications; Springer: Cham, Switzerland, 2021; pp. 1306–1312. [Google Scholar]
- Thasnim, J.; ElGhanam, E.; Hassan, M.S.; Osman, A. Towards Efficient Collaborative Delivery Solutions Using Drones and Ground Transportation: A Review. In Proceedings of the 2024 International Telecommunications Conference (ITC-Egypt), Cairo, Egypt, 22–25 July 2024; pp. 727–732. [Google Scholar]
- Evangelista, P.; Williger, B.; Gebresenbet, G.; Micheletti, S. Managing logistics and supply chain in rural areas: A systematic analysis of the literature and future directions. In New Metropolitan Perspectives: Knowledge Dynamics and Innovation-driven Policies Towards Urban and Regional Transition Volume 2; Springer: Cham, Switzerland, 2021; pp. 157–166. [Google Scholar]
- Mitton, C.; Dionne, F.; Masucci, L.; Wong, S.; Law, S. Innovations in health service organization and delivery in northern rural and remote regions: A review of the literature. Int. J. Circumpolar Health 2011, 70, 460–472. [Google Scholar] [CrossRef] [Scilit]
- Li, X.; Tupayachi, J.; Sharmin, A.; Martinez, F.M. Drone-aided delivery methods, challenge, and the future: A methodological review. Drones 2023, 7, 191. [Google Scholar] [CrossRef] [Scilit]
- Gou, M.; Yu, H. Online delivery problem for hybrid truck–drone system with independent and truck-carried drones. Sustainability 2023, 15, 1584. [Google Scholar] [CrossRef] [Scilit]
- Xia, Y.; Wu, T.; Xia, B.; Zhang, J. Truck-drone pickup and delivery problem with drone weight-related cost. Sustainability 2023, 15, 16342. [Google Scholar] [CrossRef] [Scilit]
- Park University. The Transformative Impact of Drones and Automated Technologies on Logistics. 2024. Available online: https://www.park.edu/blog/the-transformative-impact-of-drones-and-automated-technologies-on-logistics/ (accessed on 12 May 2025).
- Kim, K.; Kim, S.; Kim, J.; Jung, H. Drone-Assisted Multimodal Logistics: Trends and Research Issues. Drones 2024, 8, 468. [Google Scholar] [CrossRef] [Scilit]
- Zrelli, I.; Rejeb, A.; Abusulaiman, R.; AlSahafi, R.; Rejeb, K.; Iranmanesh, M. Drone Applications in Logistics and Supply Chain Management: A Systematic Review Using Latent Dirichlet Allocation. Arab. J. Sci. Eng. 2024, 49, 12411–12430. [Google Scholar] [CrossRef] [Scilit]
- Betti, S.F. UAV-Based Delivery Systems: A Systematic Review, Current Trends, and Research Challenges. J. Auton. Transp. Syst. 2024, 1, 1–40. [Google Scholar] [CrossRef] [Scilit]
- Belmabrouk, A.; Lahmar, A.; Chouikhi, H.; Bentaher, H. Classification framework for vehicle routing problems. In Proceedings of the 2023 IEEE Conference on Technologies for Sustainability (SusTech), Portland, OR, USA, 19–22 April 2023; pp. 161–167. [Google Scholar]
- Sadok, A.; Euchi, J.; Siarry, P. Vehicle routing with multiple UAVs for the last-mile logistics distribution problem: Hybrid distributed optimization. Ann. Oper. Res. 2025, 351, 59–99. [Google Scholar] [CrossRef] [Scilit]
- Sitek, P.; Wikarek, J.; Jagodzinski, M. A proactive approach to extended vehicle routing problem with drones (EVRPD). Appl. Sci. 2022, 12, 8255. [Google Scholar] [CrossRef] [Scilit]
- Benarbia, T.; Kyamakya, K. A literature review of drone-based package delivery logistics systems and their implementation feasibility. Sustainability 2021, 14, 360. [Google Scholar] [CrossRef] [Scilit]
- Li, X.; Gong, L.; Liu, X.; Jiang, F.; Shi, W.; Fan, L.; Gao, H.; Li, R.; Xu, J. Solving the last mile problem in logistics: A mobile edge computing and blockchain-based unmanned aerial vehicle delivery system. Concurr. Comput. Pract. Exp. 2022, 34, e6068. [Google Scholar] [CrossRef] [Scilit]
- Dai, D.; Cai, H.; Ye, L.; Shao, W. Two-Stage Delivery System for Last Mile Logistics in Rural Areas: Truck–Drone Approach. Systems 2024, 12, 121. [Google Scholar] [CrossRef] [Scilit]
- Bostan, S.; Guney, C.; Kose, U.; Aslan, S.; Kamasak, M.E. Distribution Planning and Route Optimization in Cargo Delivery. In Proceedings of the 2022 7th International Conference on Computer Science and Engineering (UBMK), Diyarbakir, Turkey, 14–16 September 2022; pp. 257–262. [Google Scholar]
- Önden, İ.; Eldemir, F. A multi-criteria spatial approach for determination of the logistics center locations in metropolitan areas. Res. Transp. Bus. Manag. 2022, 44, 100734. [Google Scholar] [CrossRef] [Scilit]
- Fischer, M.M. GIS and network analysis. In Spatial Analysis and GeoComputation: Selected Essays; Springer: Berlin/Heidelberg, Germany, 2006; pp. 43–60. [Google Scholar]
- Xiao, M.; Chen, L.; Feng, H.; Peng, Z.; Long, Q. Smart city public transportation route planning based on multi-objective optimization: A review. Arch. Comput. Methods Eng. 2024, 31, 3351–3375. [Google Scholar] [CrossRef] [Scilit]
- Bridgelall, R. Spatial Analysis of Middle-Mile Transport for Advanced Air Mobility: A Case Study of Rural North Dakota. Sustainability 2024, 16, 8949. [Google Scholar] [CrossRef] [Scilit]
- Cheng, Y.; Li, B. Systematic Analysis of The Principle and Application Cases of UAV In Logistics. Highlights Sci. Eng. Technol. 2024, 111, 82–88. [Google Scholar] [CrossRef] [Scilit]
- Ding, Y.; Wan, J.; Lin, W.; Wang, K. Coordinated last-mile deliveries with trucks and drones: A comparative study of operational modes. J. Air Transp. Res. Soc. 2024, 3, 100025. [Google Scholar] [CrossRef] [Scilit]
- Madani, B.; Ndiaye, M. Hybrid truck-drone delivery systems: A systematic literature review. IEEE Access 2022, 10, 92854–92878. [Google Scholar] [CrossRef] [Scilit]
- Chen, E.; Zhou, Z.; Li, R.; Chang, Z.; Shi, J. The multi-fleet delivery problem combined with trucks, tricycles, and drones for last-mile logistics efficiency requirements under multiple budget constraints. Transp. Res. Part E Logist. Transp. Rev. 2024, 187, 103573. [Google Scholar] [CrossRef] [Scilit]
- Zhang, J.; Campbell, J.F.; Sweeney, D.C., II. A continuous approximation approach to integrated truck and drone delivery systems. Omega 2024, 126, 103067. [Google Scholar] [CrossRef] [Scilit]
- Chu, J.C.; Shui, C.S.; Lin, K.H. Optimization of trucks and drones in tandem delivery network with drone trajectory planning. Comput. Ind. Eng. 2024, 189, 110000. [Google Scholar] [CrossRef] [Scilit]
- Khalaj, R.S.; Rahmani, D. A hybrid multi-objective solution approach for a reliable truck-drone routing problem integrated with pickup and delivery services. Transp. Lett. 2025, 17, 230–248. [Google Scholar] [CrossRef] [Scilit]
- She, R.; Ouyang, Y. Hybrid truck–drone delivery under aerial traffic congestion. Transp. Res. Part B Methodol. 2024, 185, 102970. [Google Scholar] [CrossRef] [Scilit]
- Dai, D.; Cai, H.; Wang, S. Optimization of a Cooperative Truck–Drone Delivery System in Rural China: A Sustainable Logistics Approach for Diverse Terrain Conditions. Sustainability 2025, 17, 6390. [Google Scholar] [CrossRef] [Scilit]
- Zhang, R.; Dou, L.; Xin, B.; Chen, C.; Deng, F.; Chen, J. A review on the truck and drone cooperative delivery problem. Unmanned Syst. 2024, 12, 823–847. [Google Scholar] [CrossRef] [Scilit]
- Zhen, L.; Gao, J.; Wang, S.; Laporte, G.; Yue, X. Optimizing an On-Demand Delivery Mode Based on Trucks and Drones. Transp. Sci. 2025, 59, 883–1171. [Google Scholar] [CrossRef] [Scilit]
- Wang, Y.; Yang, S.; Wang, X.V.; Wang, L. Research on truck-drone collaborative route planning for rural logistics delivery services. Sci. Rep. 2024, 14, 31815. [Google Scholar] [CrossRef] [Scilit]
- ArcGIS Online. 2024. Available online: https://www.arcgis.com (accessed on 10 April 2025).
- NC State University Libraries, Geographic Information Systems (GIS). 2024. Available online: https://www.lib.ncsu.edu/do/gis (accessed on 5 April 2025).
- U.S. Census Bureau. 2024. Available online: https://www.census.gov (accessed on 12 February 2025).
- Mohawk Global. 2024. Available online: https://mohawkglobal.com/wp-content/uploads/2020/05/Truck_Specs.pdf (accessed on 11 March 2025).
- Elroy Air. 2024. Available online: https://elroyair.com (accessed on 12 February 2025).
- ESRI. 2024. Available online: https://www.esri.com/en-us/arcgis/products/arcgis-pro/overview (accessed on 25 February 2025).

Disclaimer/Publisher’s Note: The statements, opinions and data contained in all publications are solely those of the individual author(s) and contributor(s) and not of MDPI and/or the editor(s). MDPI and/or the editor(s) disclaim responsibility for any injury to people or property resulting from any ideas, methods, instructions or products referred to in the content. |
© 2025 by the authors. Licensee MDPI, Basel, Switzerland. This article is an open access article distributed under the terms and conditions of the Creative Commons Attribution (CC BY) license (https://creativecommons.org/licenses/by/4.0/).