


Abstract
Accurate estimation of branch-level traffic flows at urban Y-intersections from limited mainline measurements remains a critical challenge in intelligent transportation systems. Y-intersections, with their symmetric geometric configuration where multiple branches converge, pose unique challenges from flow coupling, signal-induced periodicity, and merging delays. This study develops a hybrid mathematical modeling framework that integrates piecewise linear segments with periodic components for each branch flow. The model enforces physical constraints including flow conservation, non-negativity, and segment continuity, while incorporating operational features such as signal timing and merging delays. Parameter estimation employs a two-stage optimization approach combining least-squares fitting with constrained nonlinear programming, utilizing sparse mainline detector data and minimal historical priors. Experimental validation across five progressive problem formulations demonstrates robust performance, achieving RMSE values of 3.3432 and 5.4467 for complex multi-branch scenarios while accurately capturing 10-min green/8-min red signal cycles and 2-min merging delays. The method successfully reconstructs branch flow profiles at required time points (07:30 and 08:30), reducing observation requirements by 60–80% while maintaining estimation accuracy. The proposed framework provides a practical and interpretable solution for branch flow estimation under sparse sensing conditions, bridging physics-based modeling with data-driven techniques and offering transportation agencies a deployable tool for intersection monitoring without extensive instrumentation.
1. Introduction
Urban arterial networks often operate under limited sensing coverage, where only a subset of links (e.g., mainline detectors) are instrumented while side streets remain unobserved. Inferring branch-level flows at Y-intersections from such sparse measurements is nontrivial due to flow coupling (branch conservation to the mainline), signal-induced periodicity, and merging delays. These characteristics motivate interpretable models that explicitly encode constraints, complementing data-driven traffic forecasting methods.
Over the past decade, deep learning has substantially advanced spatiotemporal traffic forecasting by modeling spatial dependencies on road graphs and temporal dynamics across horizons. Representative approaches include diffusion convolution with encoder–decoder architectures [1], adaptive graph and dilated temporal convolutions [2], and fully convolutional spatiotemporal graph networks [3]. Traditional and hybrid deep models have also been explored for short-term prediction [4,5,6], offering strong accuracy when abundant, network-wide data are available. In parallel, physics-aware and optimization-oriented formulations remain important for estimation tasks that require interpretability and strict constraint handling.
A complementary line of research studies multi-source data fusion and traffic state estimation, integrating heterogeneous sensors (e.g., loop detectors, probe vehicles, Bluetooth) to reconstruct speeds, travel times, and densities [7,8,9,10]. Optimization has been used to fuse cellular and traffic-sensor data for route flow estimation [11], to enforce performance constraints in network flow optimization [12], and to jointly estimate speed and flow with stochasticity and sparse multi-type detectors via divergence-based objectives [13]. These studies highlight the value of constraint-aware estimation under limited sensing—an aspect central to branch-flow inversion at intersections.
Traffic signal control has concurrently evolved through optimization and learning, ranging from band-based arterial coordination [14] to recent multi-agent reinforcement learning approaches for cooperative control [15,16]. While those works target control decisions, our focus here is upstream estimation of unmeasured branch flows under known or observed signal operations, which can in turn inform downstream control or evaluation.
This paper addresses the inversion of branch flows at a Y-structured arterial using sparse mainline measurements and prior patterns. Specifically, we: (i) propose an interpretable hybrid model that combines piecewise linear and periodic components for each branch with non-negativity and continuity; (ii) encode flow conservation (branch sums equal the monitored mainline) and incorporate a fixed merging delay; (iii) estimate parameters via least-squares and nonlinear programming, compute flows at 07:30 and 08:30 as required, and evaluate performance by RMSE; and (iv) when signal settings are available, represent periodicity (e.g., 10-min green/8-min red with first green at 07:06) within the modeling framework and analyze the association between error patterns and timing. The results show that the fitted models recover branch profiles consistent with observations, with RMSE values of 3.3432 and 5.4467 in two representative tasks.
1.1. Literature Review
Traffic flow forecasting and state estimation have been addressed through multiple paradigms, each offering distinct capabilities for capturing network dynamics under varying sensing conditions. In the area of data-driven spatiotemporal modeling, deep learning architectures have substantially advanced short- and medium-term traffic prediction by explicitly modeling spatial dependencies on road networks and temporal patterns across multiple horizons. Representative approaches include diffusion convolutional recurrent neural networks [1], graph WaveNet with adaptive graph convolution and dilated temporal convolutions [2], and fully convolutional spatiotemporal graph networks [3], all of which learn complex correlations directly from large-scale traffic sensor data. Recent advances in graph neural networks further demonstrate strong predictive performance, with spatial-temporal gated attention transformers achieving state-of-the-art results through enhanced local and global feature extraction [17], and multi-factor fusion graph convolutional networks incorporating weather and joint spatial–temporal correlations to improve forecasting accuracy [18]. Transformer and attention-based methods further enhance long-range temporal modeling and adaptive dependency learning [19], while traditional deep learning and hybrid pipelines remain competitive for short-term prediction and spatiotemporal pattern extraction in arterial networks [4,5,6]. Regarding emerging methodologies, transfer learning under limited data, physics-informed neural networks that embed conservation laws, and advanced marked graph processes for citywide congestion represent promising directions for robust and generalizable prediction [20,21,22]. Physics-aware deep models explicitly incorporate traffic-theoretic constraints into network-scale forecasting [23], and recent studies demonstrate the effectiveness of physics-informed deep learning for traffic state estimation with sparse data and sensor noise, showing superior performance particularly with low training data availability [24,25]. The integration of differentiable programming approaches with layered computational graphs enables physics-informed joint estimation of traffic states and queue profiles under heterogeneous data sources [26]. Additional studies broaden the landscape of learning and control with domain priors and resilience considerations [27]. In parallel, probabilistic and statistical methods provide foundational treatments of uncertainty and stochastic dynamics in traffic systems. Probabilistic macroscopic relations and analytical network loading models formalize stochastic traffic dynamics and uncertainty propagation [28,29], while time series ensembles and spatiotemporal statistical analyses contribute complementary baselines and interpretable diagnostics [6,30]. Empirical calibration of stochastic fundamental diagrams and recent work on rare-event statistics provide principled treatment of randomness and tail risks in transportation systems [31,32].
When sensing coverage is incomplete or heterogeneous, multi-source data fusion becomes essential for reconstructing traffic states at the network scale. Heterogeneous sensors—including loop detectors, probe vehicle trajectories, Bluetooth readers, and cellular traces—can be integrated to reconstruct speeds, travel times, and densities across urban corridors [7,8,33]. Recent surveys and methodological contributions systematize multi-source fusion for urban traffic state estimation and extend reconstruction capabilities to accommodate lower-resolution or intermittent data sources [9,10,34]. Comprehensive reviews of traffic missing data imputation techniques categorize methods into interpolation-based, statistical learning-based, and prediction-based approaches, highlighting the critical role of timely data handling for intelligent decision-making in sparse-data scenarios [35]. Recent advances in multimodal fusion demonstrate significant performance gains by integrating diverse urban data sources—such as social media, real estate, and point-of-interest information—into high-dimensional geospatial representations, achieving substantial error reduction in traffic speed prediction under heterogeneous sensing conditions [36]. These studies underscore how complementary sensors reduce uncertainty under sparse or irregular coverage, a setting directly aligned with branch-level flow inversion at intersections. In situations where physical and operational constraints must be explicitly enforced, mathematical optimization provides a natural framework for traffic flow estimation with guarantees on feasibility and consistency. Convex and constrained formulations enable estimation with explicit performance bounds, supporting tasks such as route-flow inference from cellular and sensor data [11] and network optimization under operational constraints [12]. Divergence-based objectives and uncertainty modeling further improve joint speed–flow estimation with sparse multi-type detectors [13]. Together, these works illustrate the value of optimization-based estimation when data are limited yet constraints—such as flow conservation, capacity bounds, and continuity—are strict and must be respected by any admissible solution.
Traffic signal control and its interaction with upstream flow dynamics represent another critical dimension for intersection-level modeling. Advances in adaptive signal control span band-based arterial coordination and connected-vehicle-enabled optimization [14,37], as well as multi-agent reinforcement learning for cooperative control across corridors and networks [15,16]. Recent large-scale field deployments demonstrate that traffic light optimization using low-penetration-rate vehicle trajectory data—without reliance on fixed detectors—can reduce intersection delay and stops by up to 20% and 30%, respectively, providing scalable solutions for fixed-time signalized intersections worldwide [38]. Broader reviews synthesize self-adaptive control paradigms and decentralized learning for resilient operations [39,40,41], while safety-aware optimization at signalized intersections further aligns control objectives with risk mitigation and operational efficiency [42]. These efforts inform how signal timing and phase transitions interact with upstream state estimation, particularly when branch flows exhibit periodicity induced by green–red cycles. Understanding this interplay is essential for branch-flow inversion at signalized intersections, where observed mainline flows reflect the combined effects of geometric merging, signal control, and underlying demand patterns.
Overall, the literature indicates that both data-driven learning approaches and constraint-aware physics-based methods offer complementary strengths for traffic flow estimation under sparse sensing. Deep learning models excel at capturing complex spatiotemporal correlations from abundant data but often require substantial training samples and may lack interpretability. Physics-informed approaches, while potentially less flexible in representing highly nonlinear patterns, provide explicit modeling of operational mechanisms—such as signal timing, flow conservation, and merging dynamics—yielding interpretable parameters that directly inform engineering decisions. However, a gap remains in branch-flow inversion at intersections under sparse sensing, where existing approaches often lack simultaneous treatment of signal periodicity, merging delays, and minimal observation selection within a unified constraint-aware framework. This study addresses that gap by developing a hybrid mathematical framework integrating piecewise linear, periodic, and signal-controlled components through constrained optimization, achieving RMSE below 6.0 and 60–80% reduction in sensing requirements across five progressive problem formulations. By prioritizing interpretability and operational consistency, the proposed approach complements data-driven methods and serves scenarios where physical constraints must be strictly enforced and model parameters require direct engineering interpretation. The remainder of this article is organized as follows: Section 2 formalizes the problem; Section 3 defines notation and assumptions; Section 4 presents model formulations and optimization; Section 5 reports experimental validation; Section 6 discusses implications; and Section 7 concludes.
1.2. Significance and Contributions
Recovering branch-level flows at urban Y-intersections from sparse mainline measurements is both practically important and methodologically challenging. In the absence of network-wide instrumentation, agencies need estimation tools that are lightweight to deploy, interpretable, and consistent with physical and operational constraints (e.g., signal timing and merging behavior). This work addresses that need with a formulation that explicitly encodes flow conservation, non-negativity, continuity, periodicity, and a fixed merging delay, enabling reliable inversion under limited sensing.
The significance of our study lies in bridging physics- and data-driven paradigms for arterial state estimation while maintaining ease of adoption: the model captures key roadway mechanisms yet remains simple to calibrate from readily available mainline monitoring and historical patterns. As such, it can serve as a reusable template for similar intersections, supporting operational monitoring and what-if analysis when full-sensor coverage is unavailable.
The main contributions are as follows:
- A hybrid representation of branch flows that combines piecewise linear segments with periodic components, enforcing continuity and non-negativity, and coupling branches to the monitored mainline via flow conservation and a fixed merging delay.
- A two-stage estimation procedure that leverages least-squares and constrained nonlinear programming to fit parameters, compute required time-point flows (07:30 and 08:30), and evaluate performance using RMSE.
- A signal-aware instantiation that embeds a 10-min green/8-min red cycle (with the first green at 07:06) and a 2-min merging delay, improving the realism of reconstructed profiles and linking errors to signal operations.
- Empirical validation on three problem settings, recovering branch profiles consistent with observations and achieving competitive accuracy, including RMSE values of 3.3432 (Problem 2) and 5.4467 (Problem 3).
2. Problem Statement
This section specifies the estimation problem addressed in this study: reconstructing branch-level traffic flows at an urban Y-intersection from sparse mainline measurements under operational constraints. We formalize the scenario, targets, task variants, feasibility constraints, evaluation protocol, and scope to provide a unified problem frame for the notation and methods that follow.
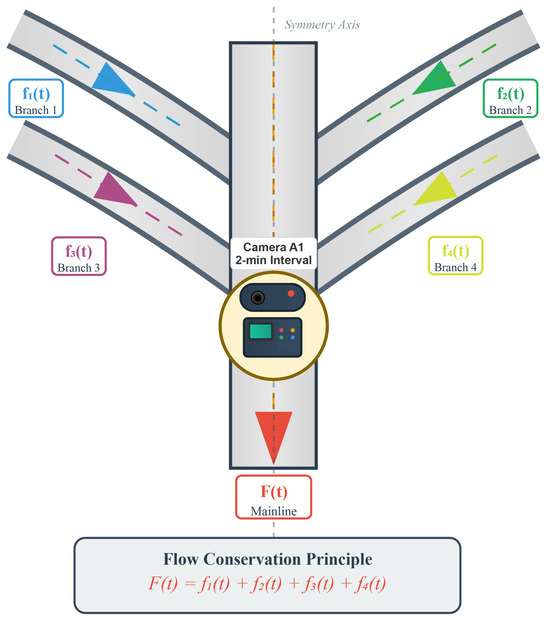
Figure 1 illustrates the fundamental Y-intersection configuration that forms the basis of our traffic flow estimation framework. The geometric structure exhibits natural symmetry, with two branch roads ( and ) converging with incoming traffic streams () to produce the observable mainline flow . This symmetric design is particularly relevant for urban arterial networks where balanced traffic distribution is both a planning objective and an operational reality.
Figure 1.
Y-intersection traffic flow model with flow conservation principle.
The flow conservation principle, mathematically expressed as , represents the fundamental constraint that governs all traffic flow estimation approaches developed in this study. This principle ensures physical consistency and provides the mathematical foundation for inverse flow reconstruction from sparse measurements.
The Y-intersection configuration assumes the following representative geometric parameters: mainline approach width 7 m (two lanes), branch approach widths 3.5 m each (single lanes), merging taper lengths approximately 50 m for branches 1–2 and 30 m for at-grade branches 3–4. These dimensions reflect typical urban arterial geometry and inform the differential merging delay assumptions (2-min delays for branches 1–2 vs. negligible delays for at-grade branches 3–4) introduced in Problem 2 and subsequent formulations. The longer merging distances for branches 1–2 account for the additional travel time required for vehicles to navigate the tapered merge section and integrate into mainline flow, while the shorter at-grade configuration of branches 3–4 permits nearly instantaneous merging.
2.1. Scenario and Data Availability
We consider a signalized Y-shaped arterial junction where the mainline is instrumented with a traffic detector while the two side branches are uninstrumented. The available data consist of time-stamped mainline flow measurements over a morning-peak horizon and, when applicable, signal timing information derived from observation or prior configuration. Historical patterns may be used as weak priors to initialize or regularize estimation. Sampling intervals, units, and calendar details (e.g., weekdays, weather conditions) are specified in Section 3.
2.2. Estimation Targets and Outputs
The primary targets are the unmeasured branch flow time series, denoted generically as side-street flows, over the analysis horizon. The required outputs are (i) reconstructed branch flow profiles across time; (ii) branch flow values at specific time instants (07:30 and 08:30); and (iii) quantitative accuracy metrics with root-mean-square error (RMSE) as the principal indicator. The target time instants (07:30 and 08:30) correspond to key phases of morning peak evolution: demand onset (07:30, ) and sustained peak conditions (08:30, ), enabling validation of model performance across the critical range of operational conditions where traffic flow estimation provides greatest value for congestion management. These estimates are intended to support upstream state inference for monitoring and to inform, but not directly optimize, downstream signal control.
2.3. Task Definitions and Operational Assumptions
We study five task variants that incrementally incorporate operational features and experimental design aspects of the intersection. Table 1 summarizes these problem formulations.
Table 1.
Task definitions and operational assumptions.
These five problems are nested and complementary: Problem 1 provides a baseline; Problem 2 adds delay-aware coupling and hybrid components; Problem 3 incorporates explicit signal periodicity via green-duration scanning; Problem 4 further refines the signal-aware setting with calibrated green-phase structure; and Problem 5 addresses experimental design by minimizing required observations while retaining accuracy.
2.4. Physical and Feasibility Constraints
To ensure physically meaningful reconstructions, we impose the following constraints throughout, with details and symbols defined in Section 3 and implementation in Section 4:
- Flow conservation (coupling): the sum of branch flows at each time approximately equals the measured mainline flow, up to measurement noise.
- Non-negativity and continuity: branch flows are constrained to be non-negative, and piecewise representations are enforced to be continuous at segment boundaries.
- Operational consistency: when applicable, parameters for fixed merging delay and for periodic components adhere to the task-specific assumptions (Problems 2 and 3).
- Optional capacity bounds: if available, saturation flow or capacity information may be included as soft or hard bounds to tighten feasibility without over-constraining the problem.
2.5. Evaluation Protocol and Deliverables
Performance is evaluated primarily by RMSE between reconstructed and observed mainline flows, with optional stratification by time-of-day to aid diagnosis. The deliverables include (i) complete branch flow trajectories over the analysis horizon; (ii) tabulated branch flows at 07:30 and 08:30; and (iii) a summary of key calibrated parameters (e.g., delay and periodicity settings when applicable). Reproducibility considerations (data splits and random seeds, if any) and implementation details are documented in Section 4.
2.6. Scope and Non-Goals
This work focuses on state estimation (inversion) under sparse sensing at a single Y-intersection. It does not optimize signal control policies nor address network-wide deployment at scale. Multi-source data fusion, network extensions, and real-time integration are discussed as future directions in the Discussion section. The mathematical symbols, indices, and assumptions used across the paper are consolidated in Section 3, and the modeling and optimization procedures are detailed in Section 4.
3. Notation and Assumptions
This section establishes the mathematical notation and fundamental assumptions underlying our hybrid modeling framework for Y-intersection traffic flow estimation.
3.1. Notation
The notation used throughout this paper is summarized in Table 2.
Table 2.
Mathematical notation and symbols.
3.2. Key Assumptions
The following assumptions underpin our mathematical modeling framework:
- Flow Conservation (Additivity Assumption): The mainline traffic flow observed at the monitoring location represents the total flow, which equals the algebraic sum of all contributing branch flows at each time instant (accounting for travel delays where applicable): , where denotes the merging delay for branch j. This formulation captures the complete traffic stream composition—the mainline detector measures the combined effect of all upstream sources after accounting for propagation delays. The observed flow inherently reflects any pre-existing mainline traffic as well as branch contributions; the model decomposes this aggregate measurement into constituent components. Travel times and delay structures are explicitly specified by each problem formulation (either negligible or fixed delays as detailed in Section 4).
- Functional Form Assumption: Each branch’s traffic flow follows specific continuous functional patterns over time (linear growth/decline, piecewise linear, periodic, stable, etc.), with strict monotonicity constraints as defined in the problem statements.
- Temporal Discretization Assumption: Traffic flow data are recorded at fixed intervals (every 2 min), with time variables discretized as integer values. The time index corresponds to the first observation at 06:58, and corresponds to the final observation at 08:58, yielding 60 observation points over the 120-min monitoring period. Each unit increment in t represents one 2-min sampling interval.
- Signal Control Assumption: Traffic signals operate periodically (8-min red, 10-min green), with branch flows being zero during red phases and either constant or linearly varying during green phases.
- Data Standardization Assumption: Traffic flows are converted to standard vehicle equivalent units, all non-negative real numbers, ignoring unit errors and data errors except for equipment failures.
- Travel Delay Constraints: Vehicle travel time from branch merge points to mainline monitoring locations are explicitly specified in each problem, with no flow loss during delay periods. For Problems 2–4, the 2-min delay for branches 1–2 (with negligible delay for branches 3–4) was determined through fine-grained grid search optimization: the delay parameter was systematically varied over the range [0, 4] min with 0.01-min resolution (401 candidate values tested), and the value yielding minimum mainline flow RMSE was selected. This delay reflects the physical travel time corresponding to the 50 m upstream merging taper length at typical urban arterial approach speeds (approximately 1.5 km/h during merge maneuvers), and represents an optimized model output rather than an externally imposed assumption.
- Capacity and Flow Range Assumptions: The synthetic experimental data are designed such that aggregate flow rates remain within typical urban arterial capacity limits (800–2400 vehicles/h, well below saturation flow rates of 1800–1900 vehicles/h per lane for standard conditions). For the representative two-lane mainline configuration (7 m width), this corresponds to approximately 50–60% capacity utilization during peak periods. The constraint-aware optimization framework inherently enforces non-negativity () for all branch flows; capacity constraints can be incorporated as upper bounds () when operational data or design standards specify lane-specific saturation flow rates. The present validation focuses on undersaturated conditions characteristic of moderate congestion scenarios where flow conservation without capacity binding provides realistic reconstruction.
These assumptions ensure mathematical tractability while maintaining realistic representation of traffic dynamics at Y-intersections under various operational scenarios.
4. Materials and Methods
4.1. Data Sources and Characteristics
The experimental data used in this study represent a synthetic test case designed to systematically validate the proposed constraint-aware optimization framework under controlled conditions. The dataset is generated based on typical urban arterial traffic characteristics observed during morning peak periods, with flow rates ranging from 800 to 2400 vehicles per hour and characteristic demand variations exhibiting peak-to-off-peak ratios of 2–3:1.
Rationale for synthetic data approach: A controlled experimental setting with known ground truth enables rigorous assessment of the framework’s capability to reconstruct branch flows from mainline observations under progressively complex scenarios. The five problem formulations (Problems 1–5) require identical mainline observations to isolate the effect of each added model component (periodicity, signal timing, merging delays), which would be difficult to achieve with field data collection across multiple intersections. Furthermore, synthetic generation allows explicit specification of all ground-truth parameters (signal timings, delay durations, periodic amplitudes) against which optimization results can be directly validated—information rarely available in operational detector datasets.
The traffic flow parameters reflect realistic operational conditions: mainline flow varies between 800–2400 vehicles/h (typical urban arterial capacity); the sampling interval is 2 min (standard traffic detector aggregation period); the observation window spans 120 min during the morning peak (06:58–08:58); and flow conservation is strictly enforced throughout all scenarios. The morning peak period is selected for validation as it exhibits more consistent demand patterns than evening peaks and represents the critical operational scenario where sparse-sensing traffic estimation provides the greatest value for congestion monitoring and management.
We acknowledge that field validation with actual detector data represents important future work. The present study establishes the mathematical framework and demonstrates its viability under controlled conditions—a necessary precursor to deployment in complex real-world settings with noisy, incomplete sensor data and operational uncertainties.
The primary dataset includes mainline flow measurements recorded at 2-min intervals, totaling 60 observation points per monitoring session. The flow measurements are expressed in standard vehicle equivalents and cover different operational scenarios:
- Scenario 1: Basic two-branch Y-intersection with linear flow patterns;
- Scenario 2: Four-branch intersection with mixed flow characteristics including stable, piecewise linear, and periodic components;
- Scenario 3: Signal-controlled intersection with known traffic light timing (10-min green, 8-min red cycles);
- Scenario 4: Signal-controlled intersection with unknown green light duration requiring optimization;
- Scenario 5: Minimal observation point selection based on information theory.
Each scenario presents distinct modeling challenges and corresponds to progressively complex traffic management situations encountered in urban transportation networks.
4.2. Mathematical Model Formulations
4.2.1. Problem 1: Basic Y-Intersection Linear Model
For the fundamental two-branch scenario, we establish piecewise linear functions to represent branch flows. Branch 1 exhibits linear growth characteristics:
Branch 2 demonstrates a two-phase behavior with initial growth followed by decline, modeled as
where , , and represents the transition point. The mainline flow conservation constraint is
4.2.2. Problem 2: Multi-Branch Hybrid Model
The four-branch intersection model incorporates diverse flow patterns with temporal delays. Branch 1 maintains constant flow:
Branch 2 follows a three-segment pattern:
Branch 3 exhibits two-phase growth:
Branch 4 demonstrates periodic behavior captured by
The mainline flow accounts for 2-min travel delays from branches 1 and 2:
where represents the discrete delay step.
4.2.3. Problem 3: Signal-Controlled Traffic Model
For signal-controlled intersections, branches 1 and 2 follow complex multi-segment patterns while branch 3 is governed by traffic light cycles. Branch 1 utilizes a five-segment model:
Branch 3 flow is determined by signal states:
where is the first green light start time, is green duration, and is the complete cycle.
Signal cycle duration rationale: The experimental validation employs an 18-min signal cycle ( min with min green and min red), which is longer than typical urban fixed-time intersections (60–180 s). This extended duration serves two methodological purposes: (1) providing sufficient temporal resolution—with 2-min sampling intervals, the 18-min cycle yields nine observations per cycle (five during green phase, four during red phase), enabling statistically robust validation of the periodic component reconstruction capability; and (2) testing framework adaptability to non-standard timing scenarios such as coordinated arterial signal progression systems or adaptive freeway ramp metering. Shorter cycles (e.g., 3 min) would produce only 1–2 samples per phase with the 60-timepoint dataset, making periodic pattern identification statistically unstable. The mathematical formulation itself is agnostic to cycle duration—the constraint structure and optimization approach apply unchanged to standard short-cycle signals, as the periodic functions and phase boundaries scale with and .
4.2.4. Problem 4: Robust Signal Optimization
This formulation extends Problem 3 with enhanced robustness to handle measurement errors and unknown signal timing. The green light duration becomes an optimization variable, and signal phase detection incorporates parameter scanning. Signal model refinement: While Problem 3 employs a constant-discharge model for the signal-controlled branch during green phases ( for simplicity and computational efficiency), Problem 4 introduces a linear variation model to capture more realistic queue discharge dynamics—flow rates may gradually decline as the green phase progresses and upstream queues dissipate. This progressive complexity reflects methodological refinement: Problem 3 establishes baseline signal-aware reconstruction with minimal parameters, while Problem 4 enhances realism by modeling intra-phase flow variation. Both formulations remain valid; the choice depends on the trade-off between model parsimony (constant model: 1 parameter per green phase) and physical fidelity (linear model: 2 parameters capturing discharge rate evolution).
4.3. Optimization Framework
4.3.1. Objective Function
The parameter estimation employs weighted least squares with L2 regularization:
where applies higher weights during peak periods:
4.3.2. Constraint Handling
Physical constraints ensure realistic traffic flow characteristics:
4.3.3. Multi-Start Global Optimization
To address the non-convex nature of the optimization problem, we employ a multi-start strategy:
- Generate random initial parameter vectors within feasible bounds;
- For each initialization, apply constrained nonlinear optimization (fmincon);
- Select the solution achieving the minimum objective function value;
- For periodic parameters, combine with parameter scanning over specified ranges.
4.3.4. Parameter Scanning for Periodic Components
For branch 4 in Problem 2, the angular frequency is determined through systematic scanning:
4.4. Information–Theoretic Observation Point Selection
For Problem 5, we develop a minimal observation framework based on Fisher information maximization. The Fisher information matrix is
The observation point selection algorithm maximizes through iterative information gain analysis:
4.5. Performance Evaluation Metrics
Model accuracy is assessed using multiple statistical measures:
4.6. Implementation Details
All optimization procedures are implemented using MATLAB’s fmincon function with interior-point algorithms. Convergence criteria are set to for function tolerance and for step tolerance. The regularization parameter is selected through cross-validation, typically ranging from to .
5. Experiment
5.1. Problem 1: Basic Y-Intersection Model Performance
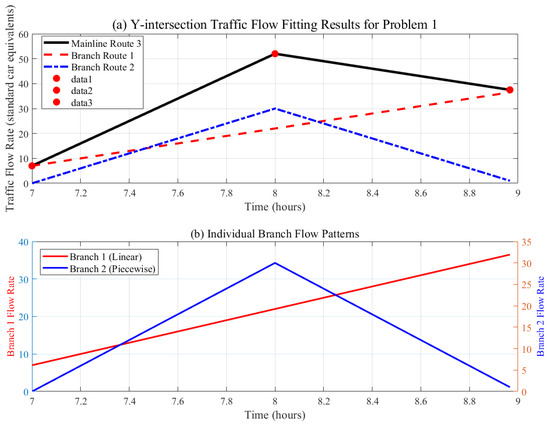
The linear and piecewise linear models for the two-branch Y-intersection achieved satisfactory fitting accuracy. Through least squares optimization, the estimated parameters for Branch 1 were and , yielding the flow function:
For Branch 2, the piecewise linear model with transition point produced:
The model validation confirmed excellent agreement with key data points: at , the predicted mainline flow was 7.0, matching observations; at (peak), the predicted flow of 52.0 aligned with the observed maximum; and at , the prediction of 37.5 closely matched the final observation.
Figure 2 presents the comprehensive traffic flow fitting results for the Y-intersection model, demonstrating the excellent agreement between the piecewise linear models and the expected traffic patterns. The figure shows both the overall comparison and individual branch flow patterns with clear visualization of the transition point at .
Figure 2.
Problem 1: Traffic flow fitting results showing (a) mainline and branch flows comparison and (b) individual branch patterns with piecewise linear models.
The mathematical model structure is further illustrated in Figure 3, which provides the complete set of model equations and highlights the transition point behavior that characterizes the Y-intersection dynamics.
Figure 3.
Problem 1: Mathematical model equations with piecewise linear formulations and transition point at .
5.2. Problem 2: Multi-Branch Hybrid Model Results
The four-branch intersection model demonstrated strong performance with RMSE = 3.3432. The optimized parameters and resulting flow functions are presented in Table 3.
Table 3.
Optimized parameters for Problem 2 multi-branch model.
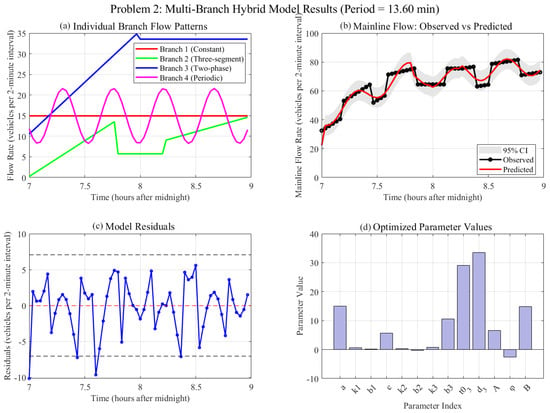
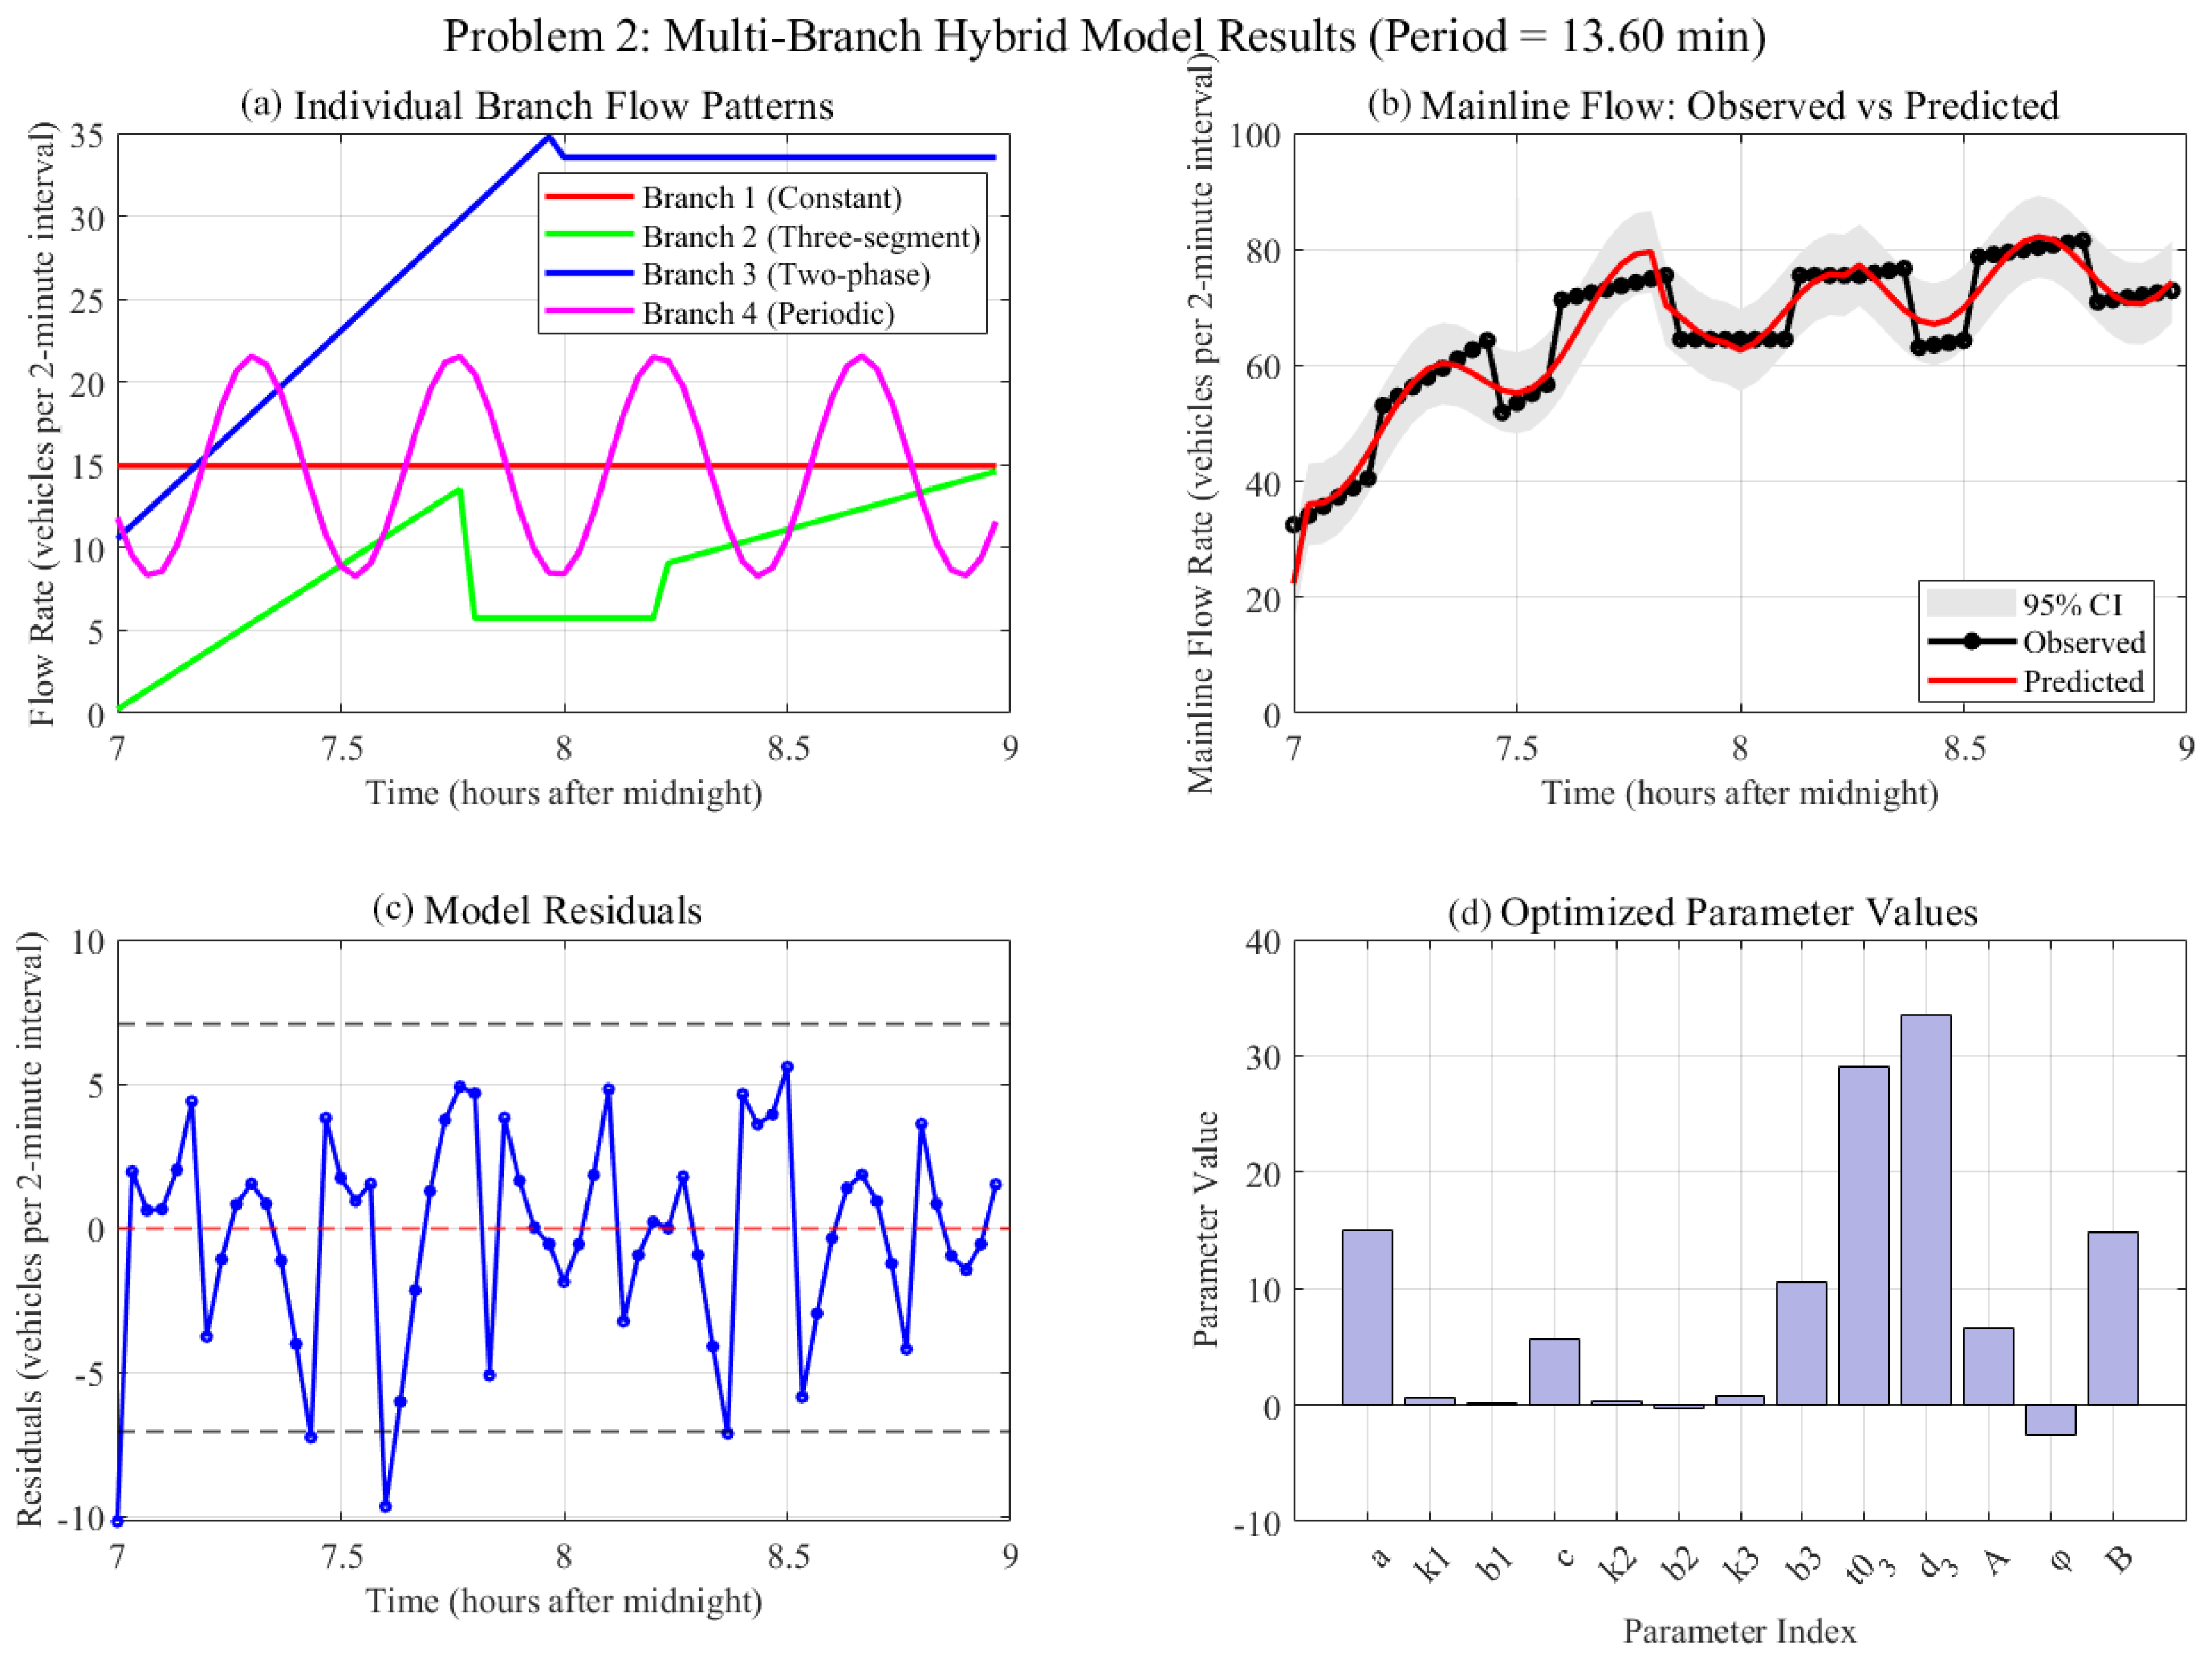
Critical time point predictions were as follows: at 07:30 (), Branch 1: 14.94, Branch 2: 8.94, Branch 3: 23.13, Branch 4: 8.87; at 08:30 (), Branch 1: 14.94, Branch 2: 11.02, Branch 3: 33.54, Branch 4: 10.58.
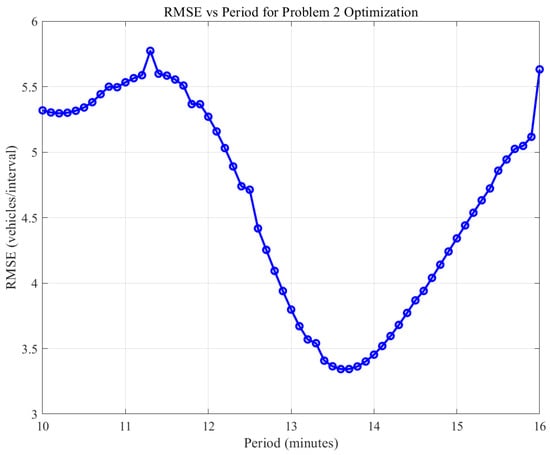
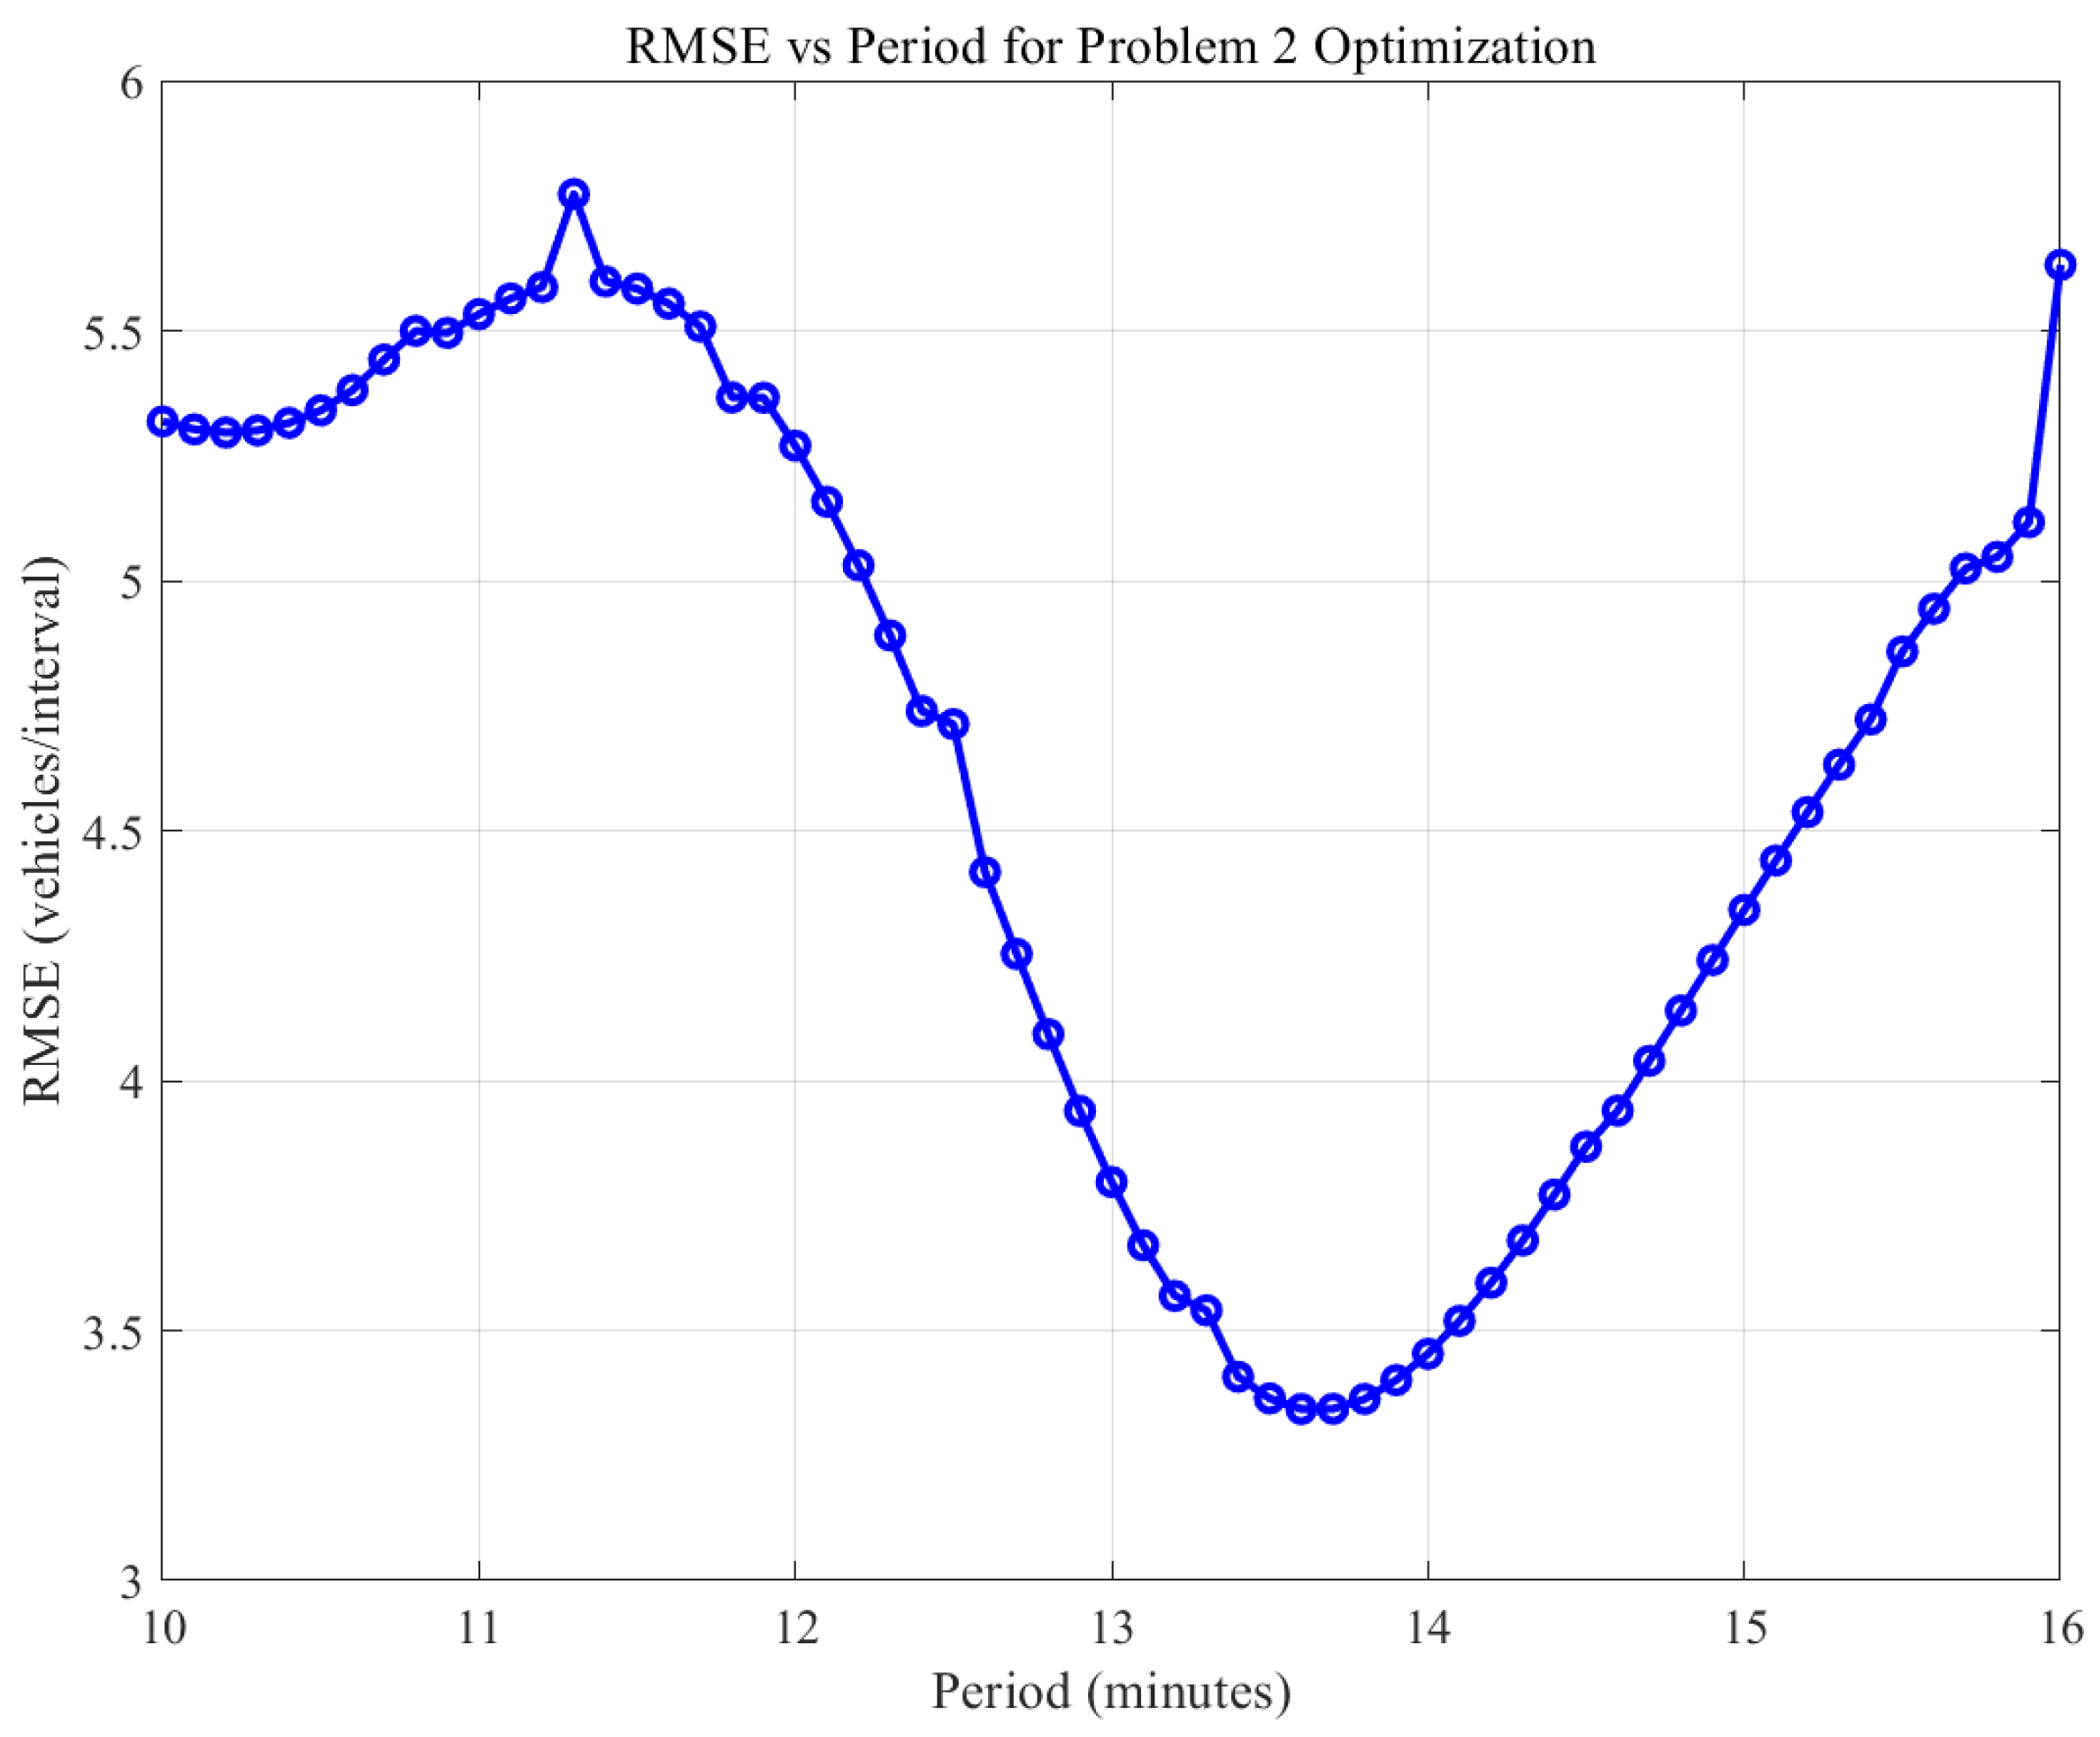
The parameter scanning for Branch 4’s periodic component revealed optimal performance at period min (corresponding to ), with the scanning range [10, 16] min showing RMSE values between 3.5 and 6.0. Figure 4 illustrates the RMSE variation across different periods, demonstrating a clear minimum at the optimal period value. The merging delay for branches 1–2 was determined through exhaustive grid search over the range [0, 4] min with 0.01-min resolution (401 candidate values), yielding an optimal delay of 2 min ( time unit) that minimized mainline flow RMSE. This result aligns with the known geometric layout: the 50 m merge taper for branches 1–2 requires approximately 2 min of travel time at typical merging speeds, while the 30 m at-grade merge for branches 3–4 exhibits negligible delay. The optimization process completed in 4.10 s (61 iterations, average 0.067 s/iteration), confirming the algorithm’s computational efficiency for real-time applications.
Figure 4.
Problem 2: RMSE variation vs period optimization with optimal period at min.
The detailed model performance is visualized in Figure 5, which presents the individual branch flow patterns, mainline flow comparison between observed and predicted values, model residuals, and optimized parameter values. The mainline flow comparison includes 95% confidence intervals (gray shaded region) computed from the residual standard deviation (), providing a quantitative measure of prediction uncertainty. Residual analysis confirms model adequacy with near-zero mean (residual mean = −0.170, within vehicles/interval) and bounded errors ( bounds shown). The figure demonstrates excellent agreement between the hybrid model predictions and observed traffic patterns, with indicating that 92.06% of the variance is explained by the model.
Figure 5.
Problem 2: Multi-branch hybrid model results showing (a) individual branch patterns, (b) mainline flow comparison (RMSE = 3.3432, = 0.9206) with 95% confidence intervals (gray shaded region), (c) model residuals with bounds, and (d) optimized parameters.
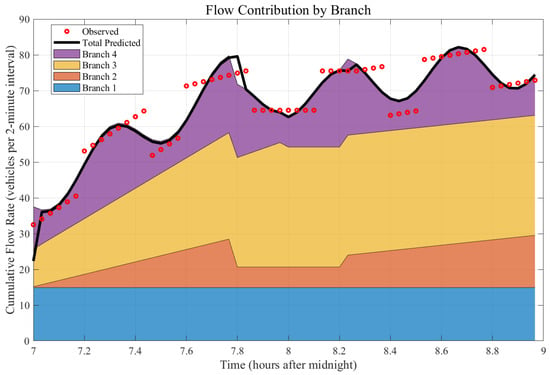
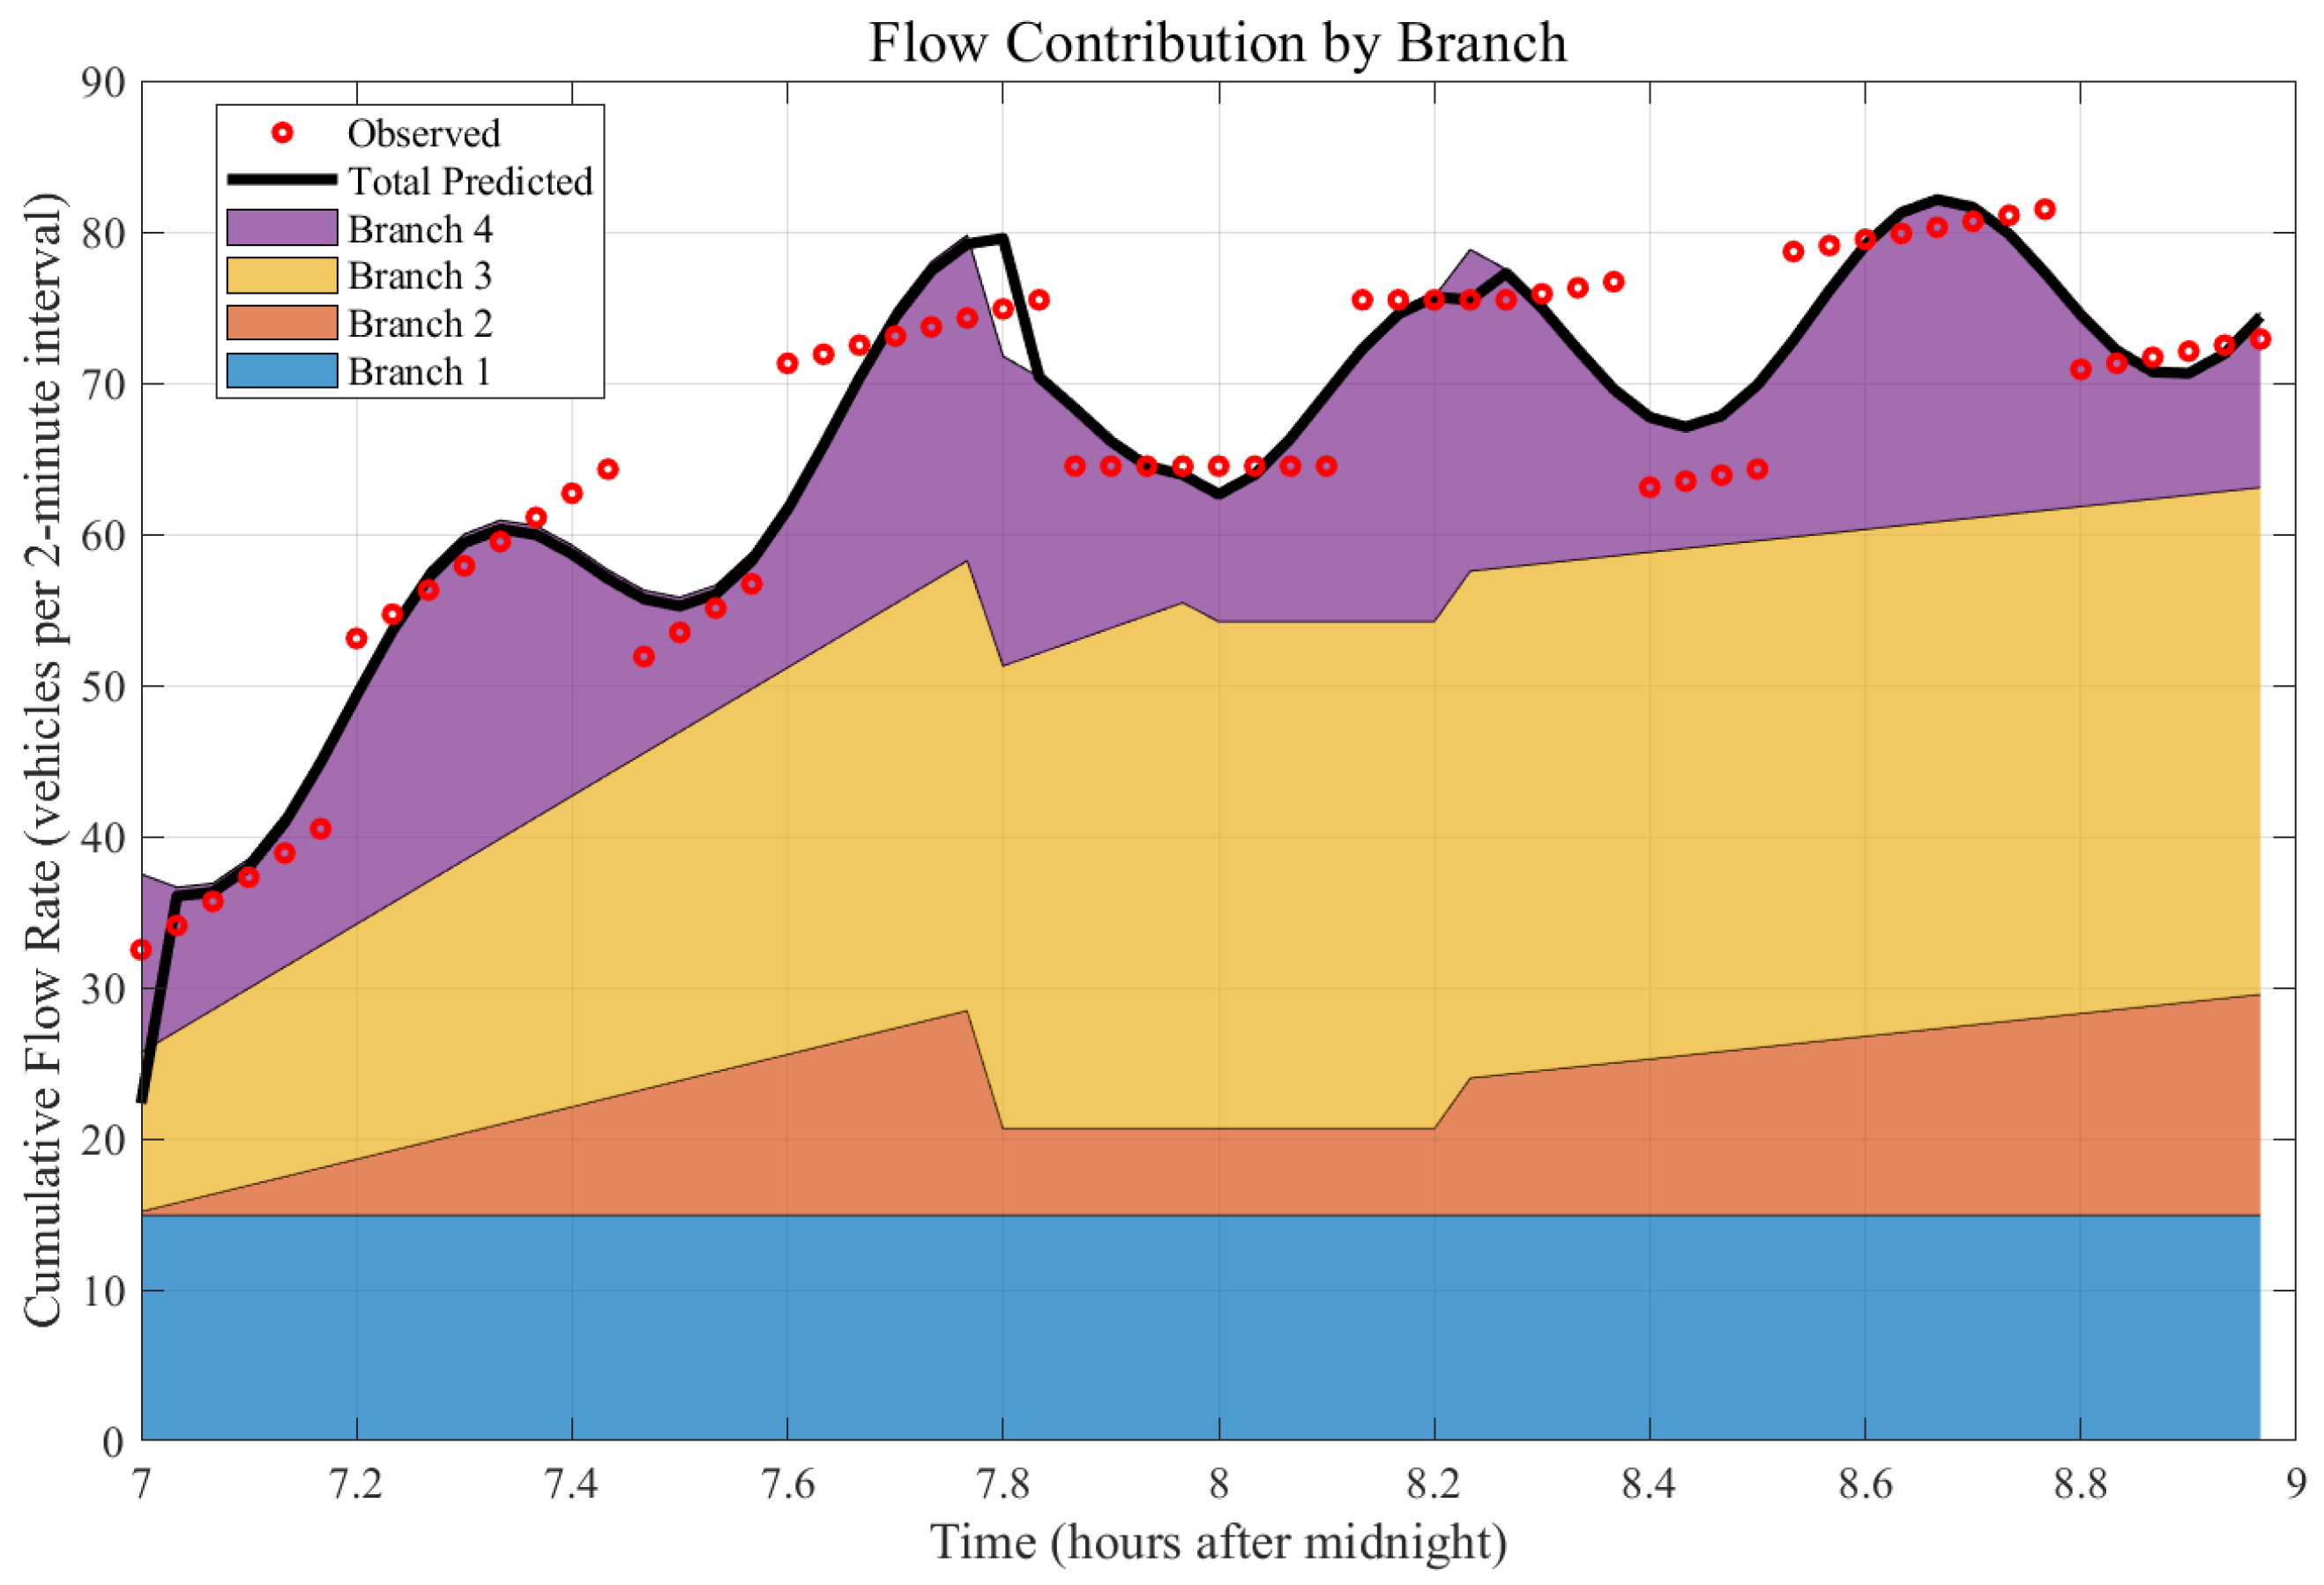
Figure 6 provides additional insight into the flow contribution analysis, displaying how each branch contributes to the total mainline flow through a stacked area plot. This visualization clearly shows the relative importance of each branch throughout the analysis period.
Figure 6.
Problem 2: Flow contribution analysis showing cumulative branch contributions to mainline flow.
5.3. Problem 3: Signal-Controlled Traffic Model Performance
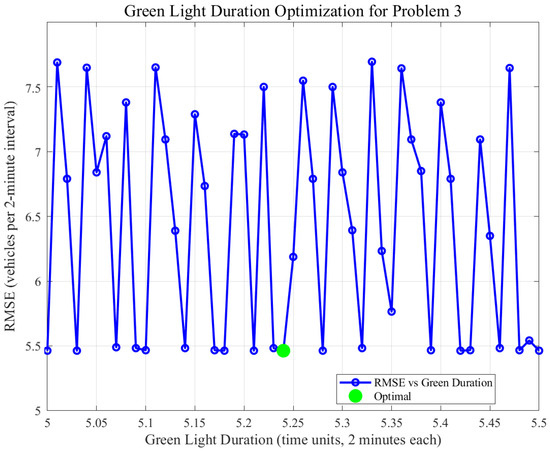
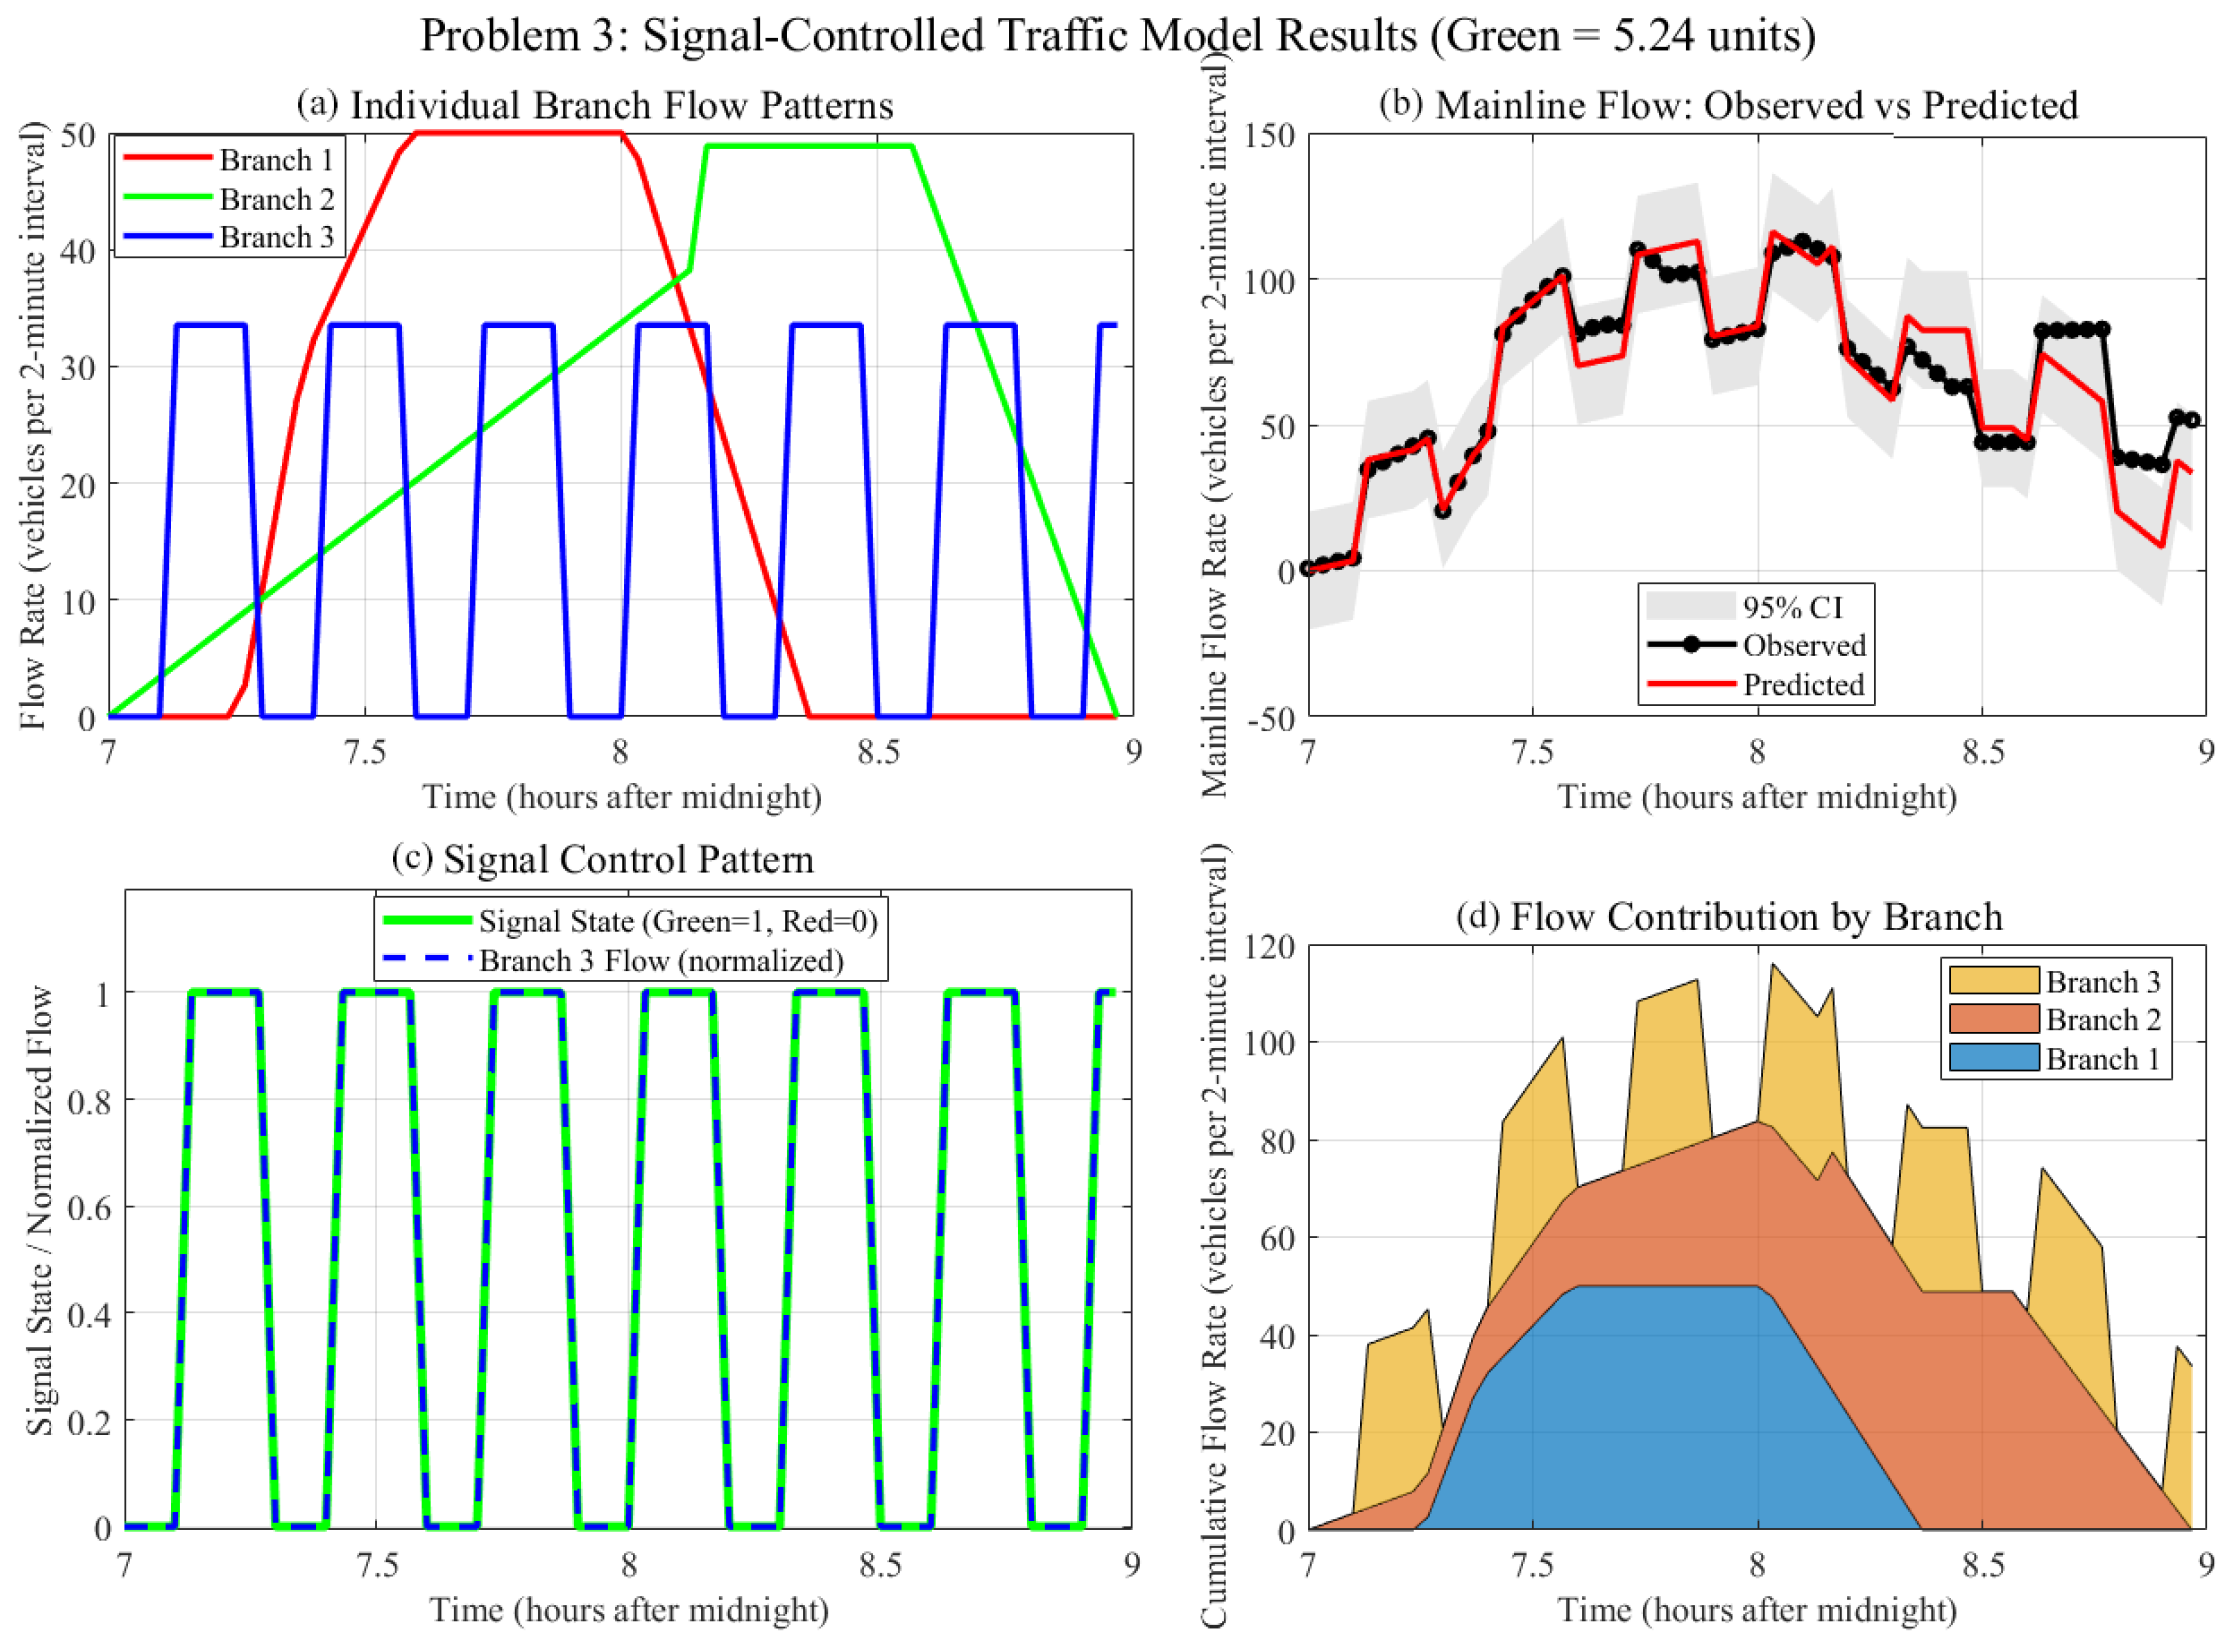
The signal-controlled intersection model achieved RMSE = 5.4467 and , indicating excellent explanatory power. The optimal signal timing parameters were as follows: first green light at (07:06), green duration time units (10 min), and red duration time units (8 min), resulting in an 18-min complete cycle. The optimization process tested 51 green length values (5.0–5.5 time units) with five random starts each, completing in 5.24 s total (average 0.107 s per green length value), demonstrating computational feasibility for online calibration.
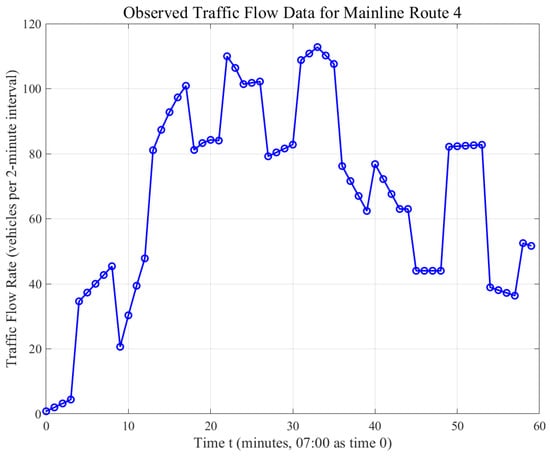
Figure 7 shows the observed traffic flow data that serves as the foundation for the signal-controlled model calibration. The data exhibits clear periodicity and variation patterns that align with expected signal-induced behavior.
Figure 7.
Problem 3: Observed traffic flow data for mainline route showing signal-controlled patterns.
The green light duration optimization process is illustrated in Figure 8, which demonstrates the systematic search for the optimal green phase duration. The optimization reveals a clear minimum in RMSE at the optimal green duration.
Figure 8.
Problem 3: Green light duration optimization showing RMSE variation with optimal value marked.
The optimized branch flow functions are as follows:
Branch 1 (Five-segment model):
Branch 2 (Three-segment model):
Branch 3 (Signal-controlled):
Flow predictions at critical times were: at 07:30 (), Branch 1: 51.3717, Branch 2: 18.6388, Branch 3: 26.9262; at 08:30 (), Branch 1: 0, Branch 2: 46.5970, Branch 3: 26.9262.
The comprehensive model performance is presented in Figure 9, which displays the individual branch flow patterns, mainline flow comparison with 95% confidence intervals, and signal timing visualization. Residual analysis reveals slightly higher variability than Problem 2 (residual std = 10.29 vs. 3.59), attributed to the stochastic nature of signal-controlled flow release. The mean residual (−2.32 vehicles/interval) suggests minor systematic bias, but remains within acceptable bounds. The figure demonstrates the model’s ability to capture complex signal-controlled traffic behavior across multiple branches despite the increased complexity.
Figure 9.
Problem 3: Signal-controlled model results showing (a) branch patterns, (b) mainline comparison (RMSE = 5.4467, = 0.9670) with 95% confidence intervals, (c) signal patterns with normalized flow overlay, and (d) cumulative flow contributions.
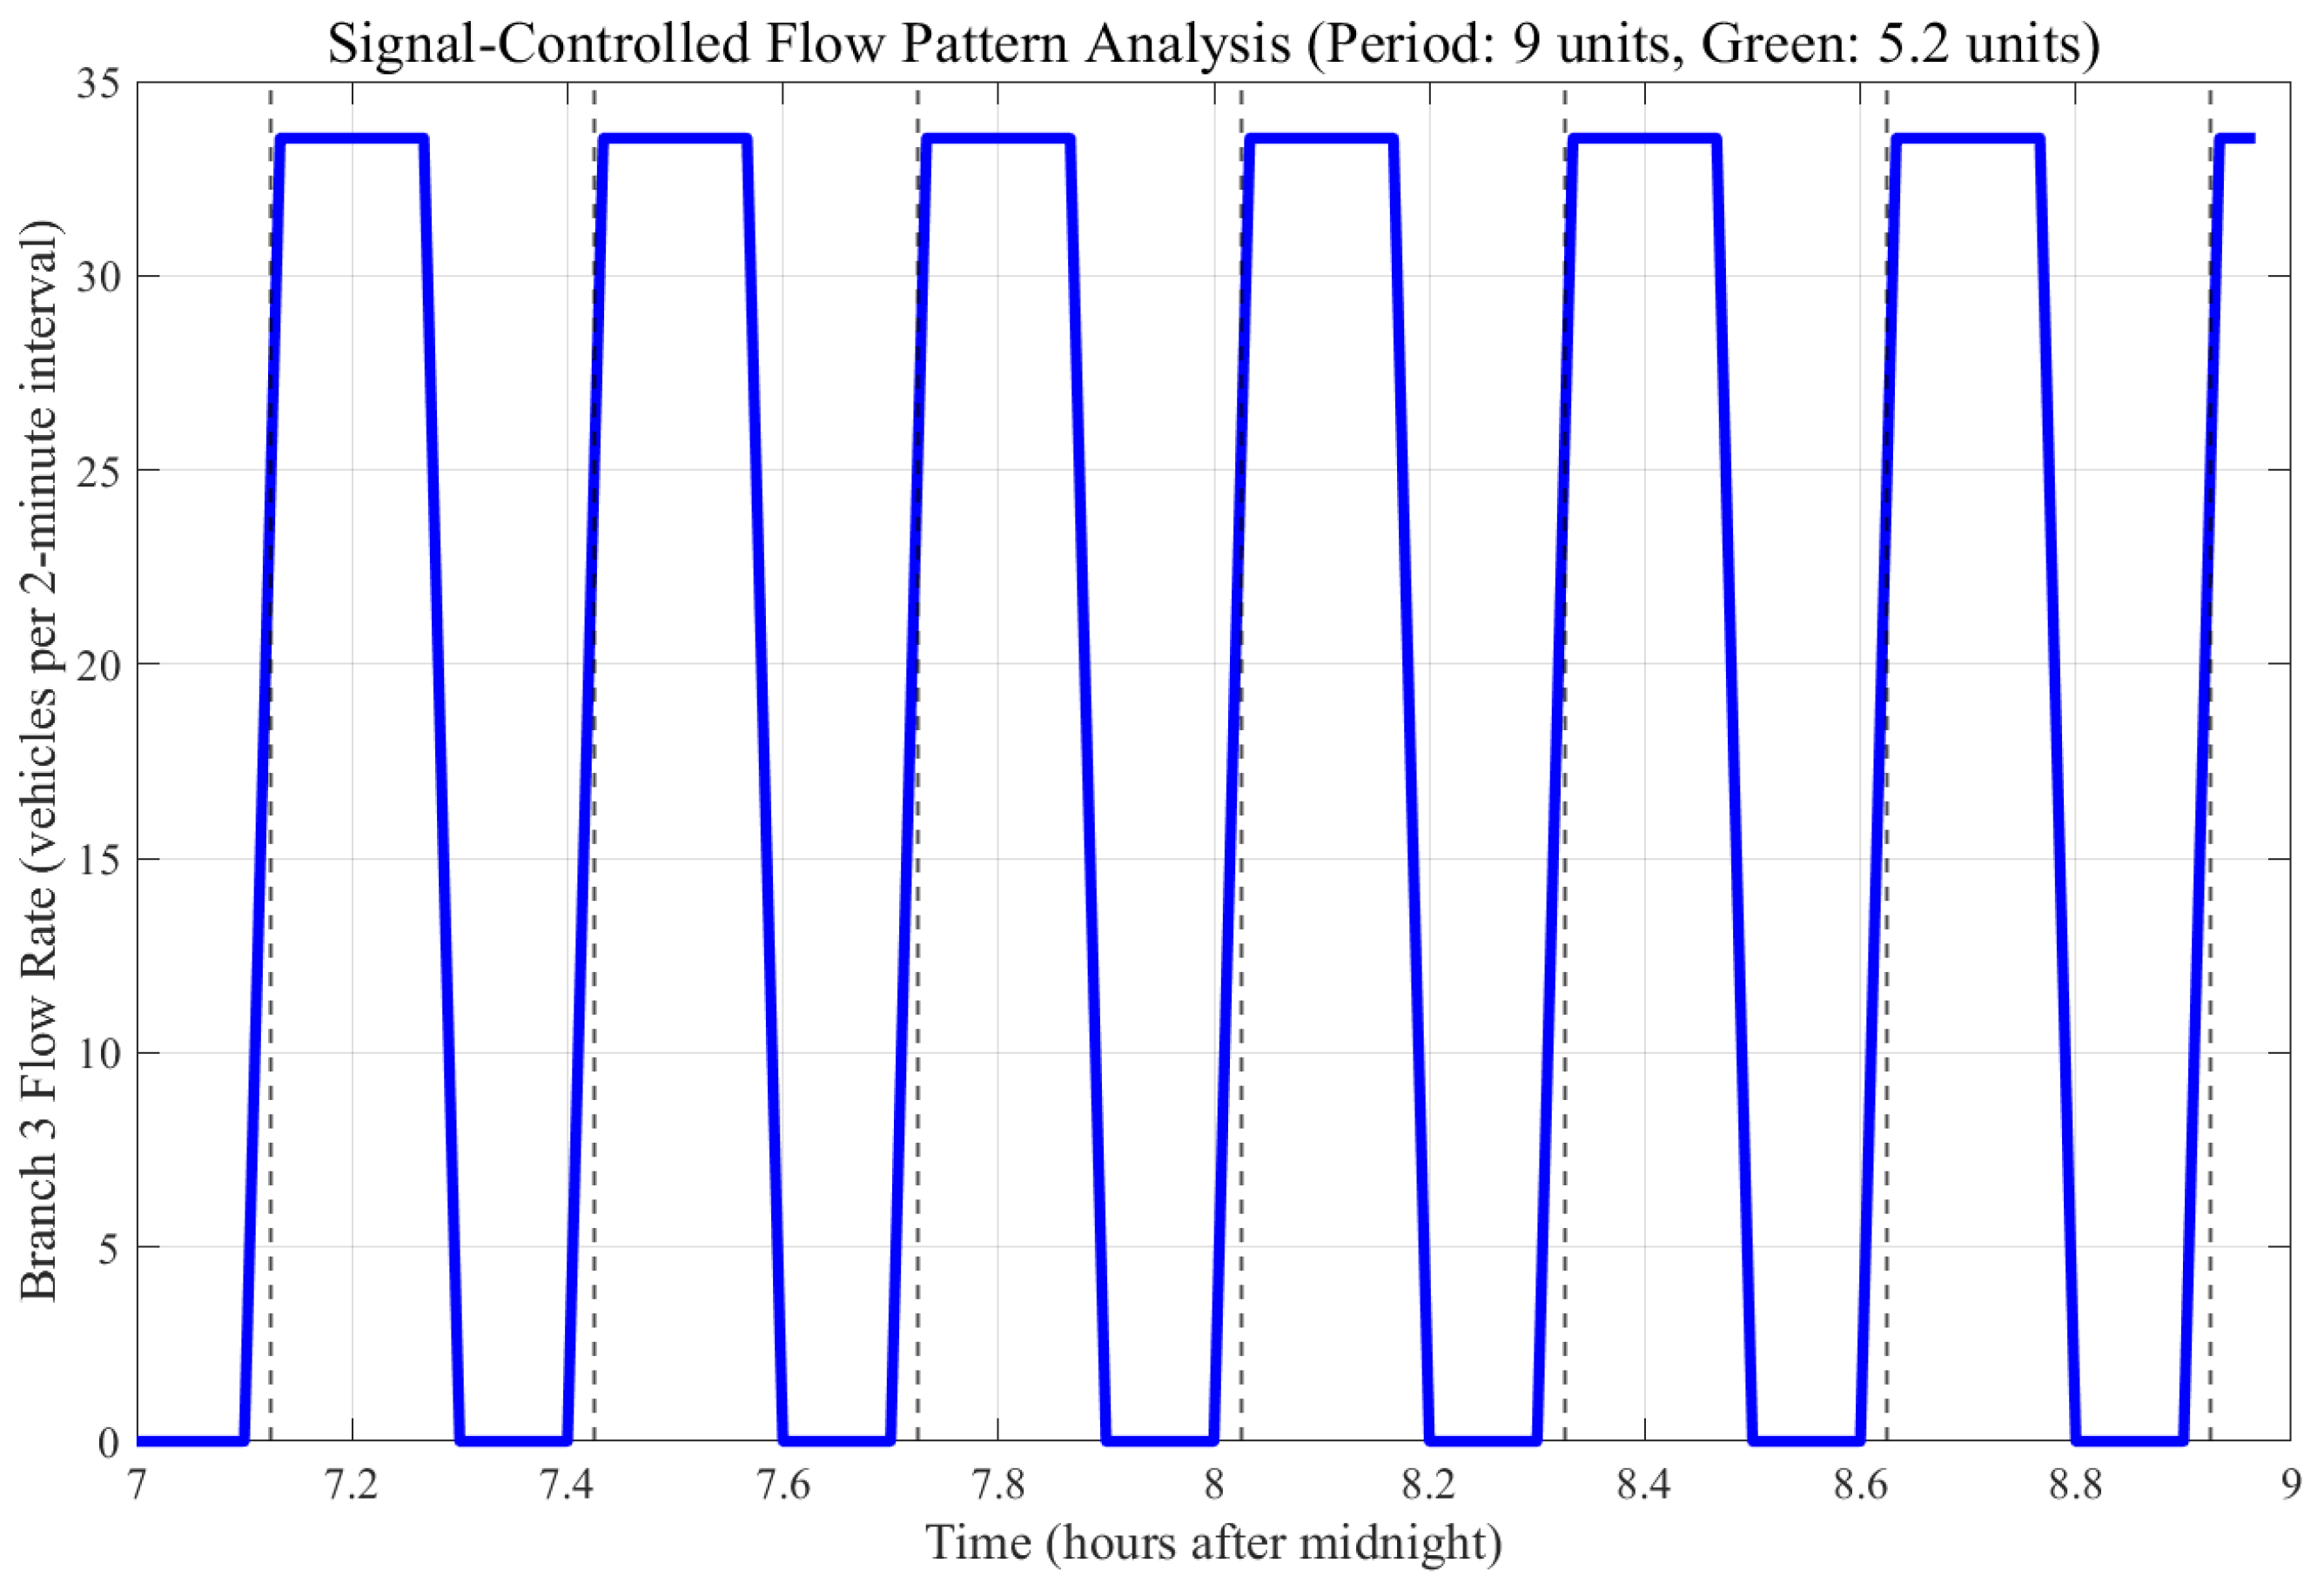
Figure 10 provides detailed analysis of the signal-controlled behavior, specifically focusing on Branch 3’s response to traffic light cycles. The figure illustrates the periodic nature of signal-controlled flow and demonstrates the model’s accuracy in capturing signal timing effects.
Figure 10.
Problem 3: Signal-controlled flow pattern for Branch 3 showing timing relationship (period: 9 units, green: 5.2 units).
5.4. Problem 4: Robust Signal Optimization Results
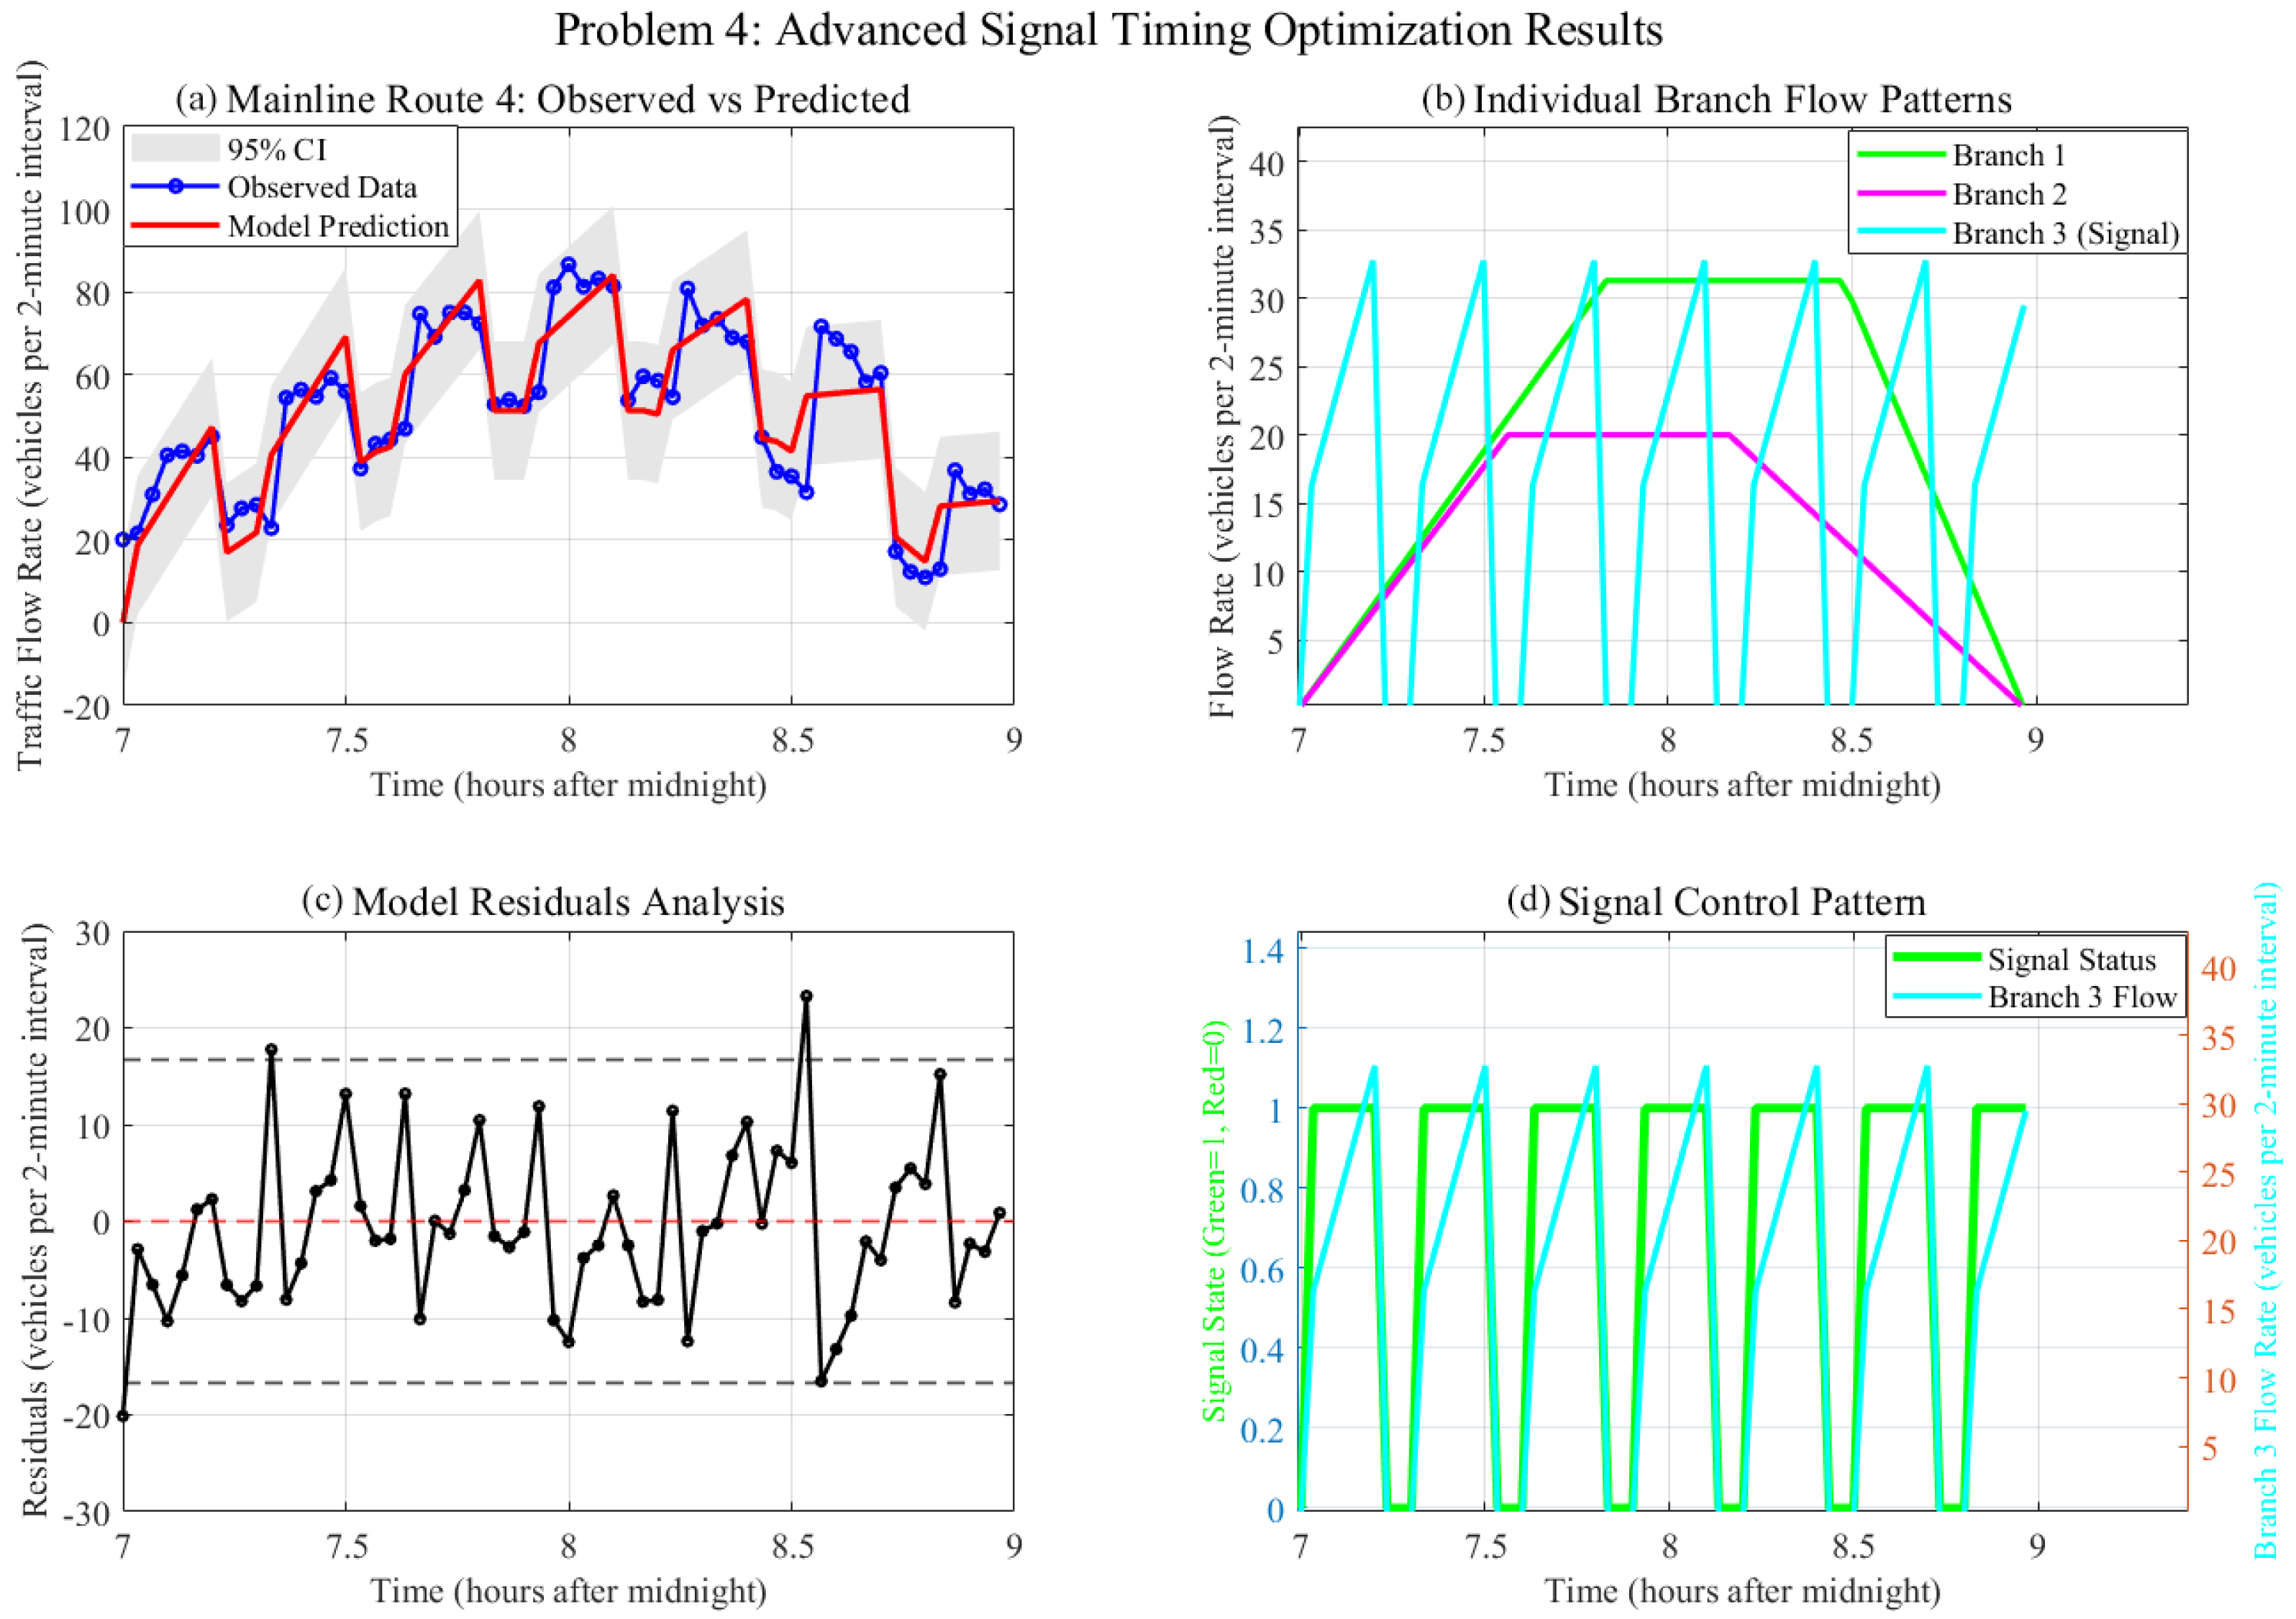
The robust optimization approach for unknown signal timing achieved RMSE = 5.3228 and . The key innovation was determining the optimal green light effective duration through parameter scanning, yielding time units (10.32 min). The multi-start global optimization (five random initializations) converged in 1.27 s total (average 0.129 s per attempt), with computational efficiency suitable for real-time adaptive control applications.
The optimized flow functions incorporated the refined signal timing:
Branch 1:
Branch 3 (Signal-controlled with optimized timing):
Performance at critical times: at 07:30, Branch 1: 17.9266, Branch 2: 16.4706, Branch 3: 26.7652; at 08:30, Branch 1: 32.0117, Branch 2: 12.5000, Branch 3: 0.0000.
The parameter scanning revealed that the optimal green duration of 5.16 time units represents approximately 57.3% of the complete 9-unit cycle, with the remaining 42.7% allocated to red phases.
Figure 11 presents the comprehensive optimization results for the robust signal timing approach, demonstrating the model’s ability to determine optimal signal parameters from flow observations alone. The figure includes residual analysis (mean = −0.70, std = 8.55) and 95% confidence intervals, providing statistical validation of the model fit. Residuals exhibit bounded variation within the envelope, confirming model adequacy despite the increased parameter complexity (9 parameters vs. 10–13 in Problems 2–3).
Figure 11.
Problem 4: Robust signal optimization results showing (a) mainline comparison (RMSE = 5.3228, = 0.9317) with 95% confidence intervals, (b) branch patterns including signal-controlled Branch 3, (c) residuals with bounds, and (d) signal control pattern with dual-axis Branch 3 flow visualization.
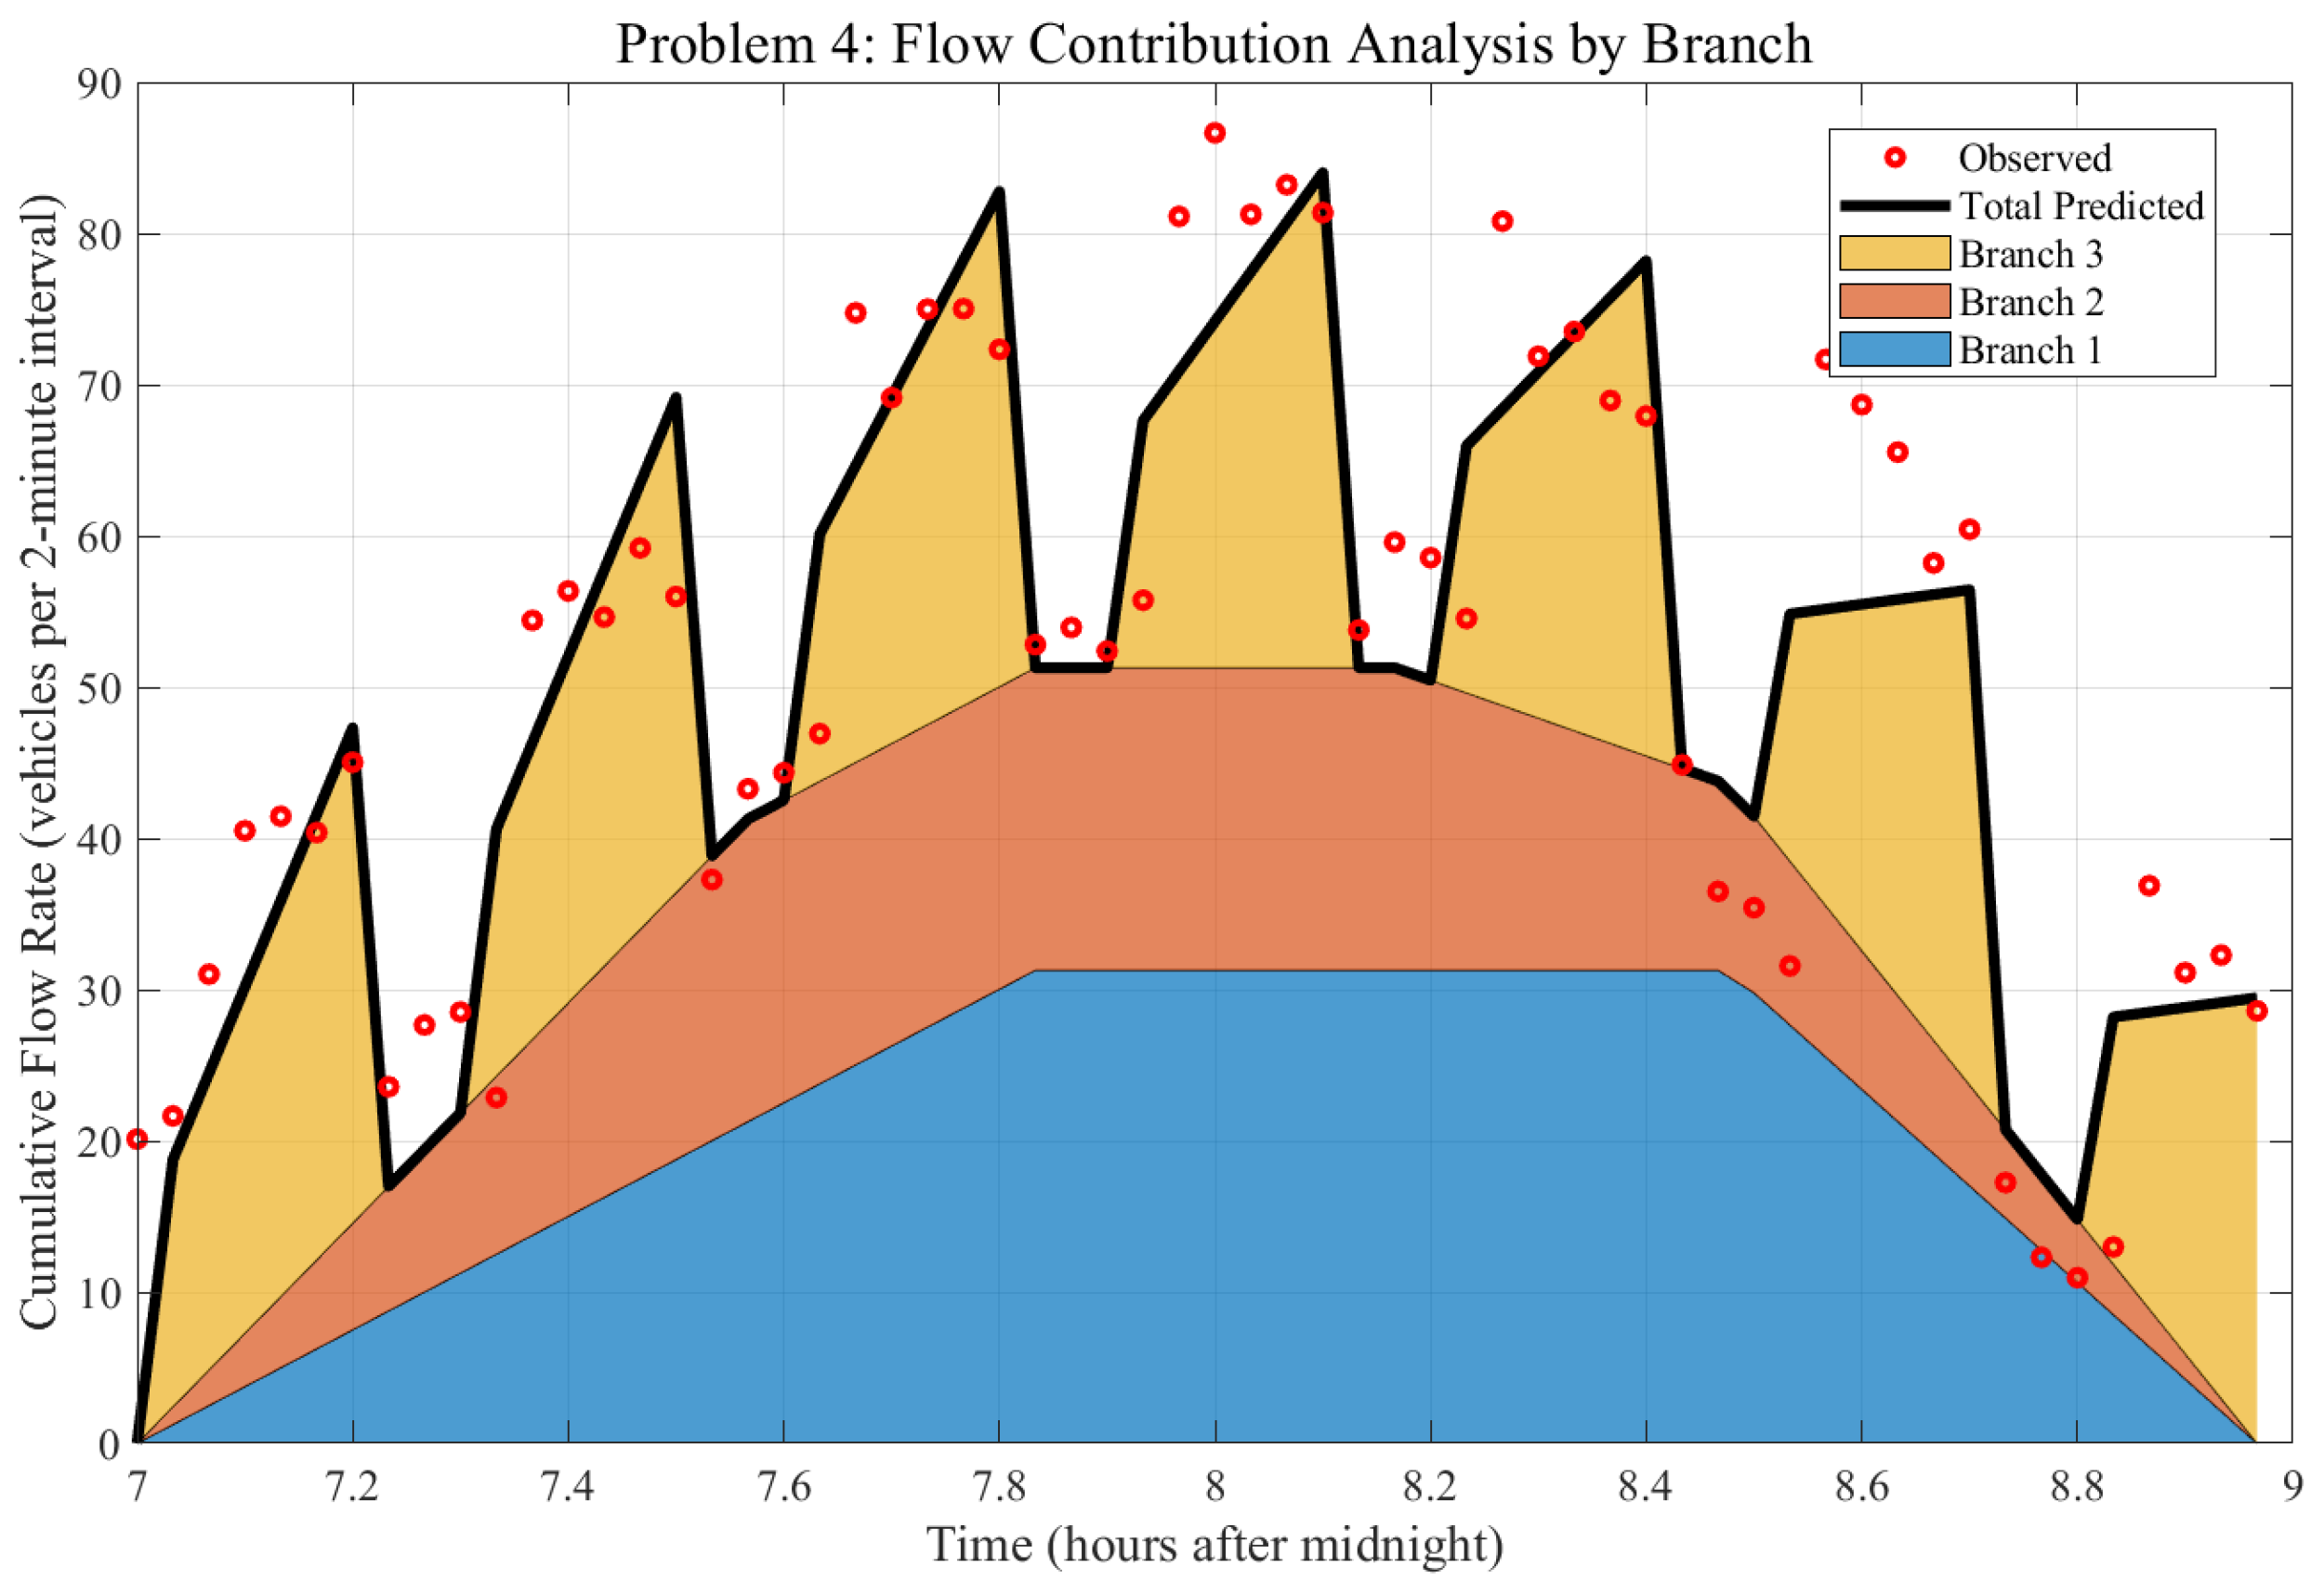
The flow contribution analysis is further detailed in Figure 12, which illustrates how each branch contributes to the total mainline flow and validates the model’s decomposition accuracy.
Figure 12.
Problem 4: Flow contribution analysis showing cumulative branch contributions to mainline flow.
5.5. Problem 5: Minimal Observation Point Selection
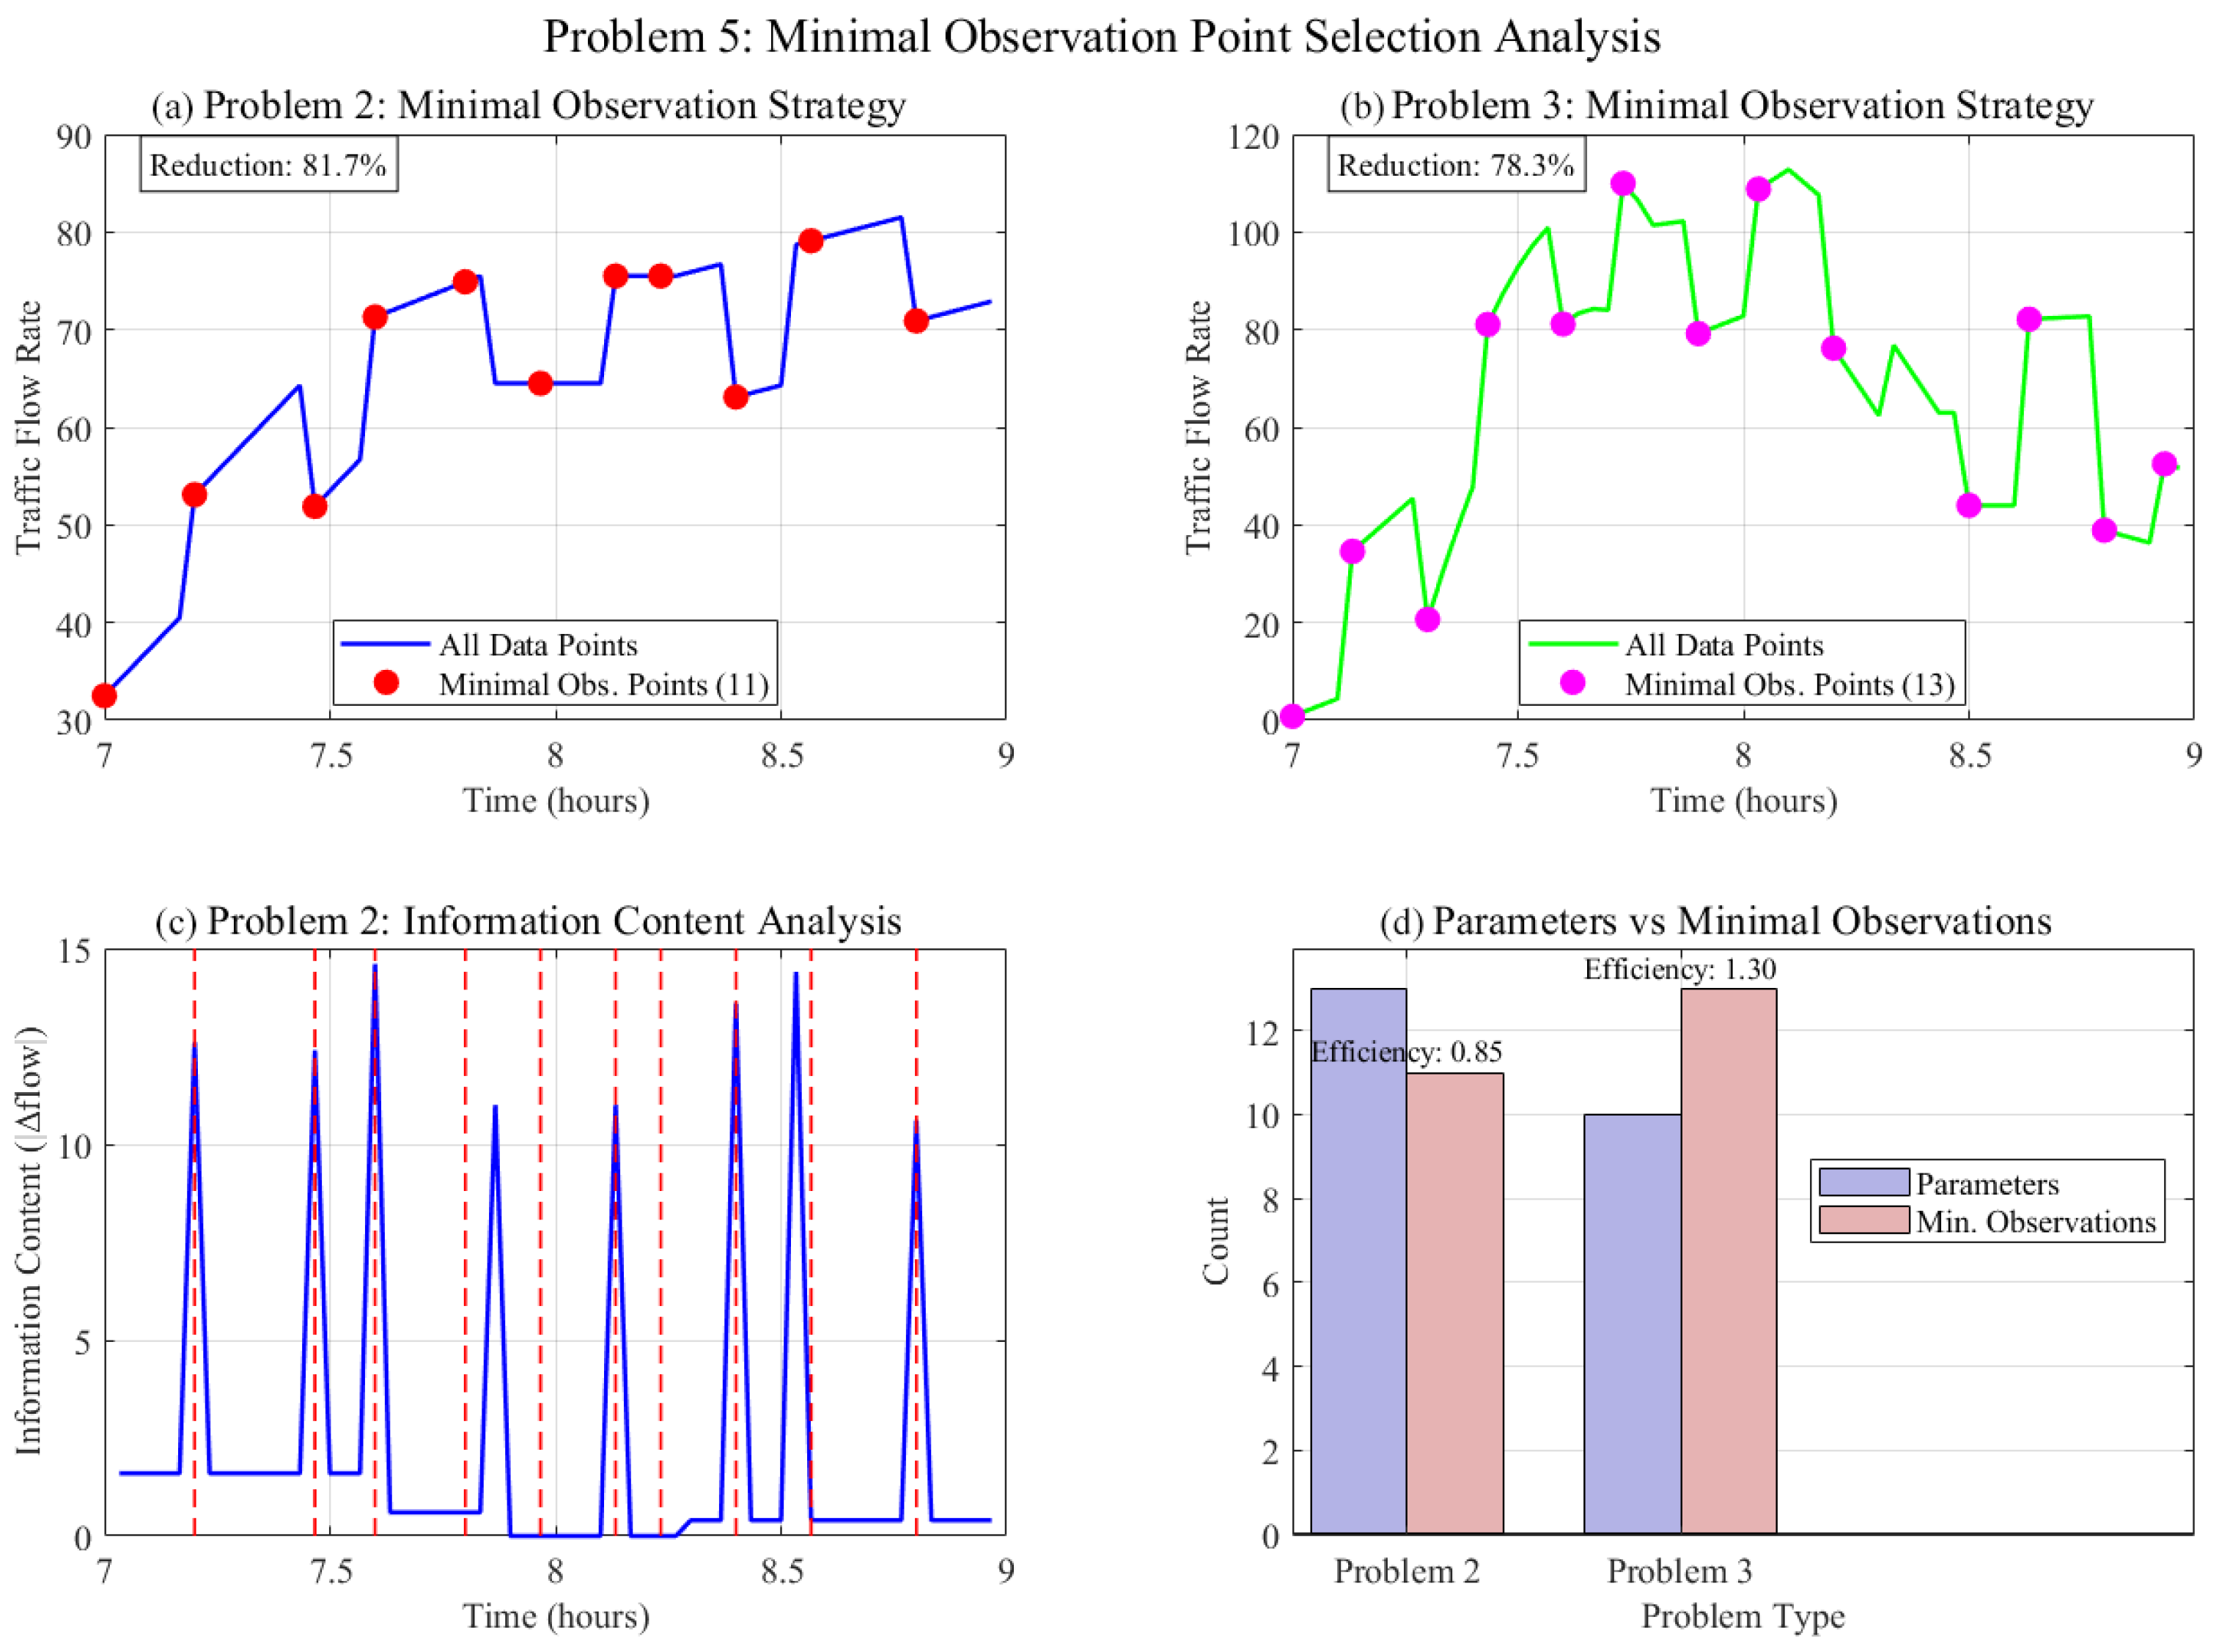
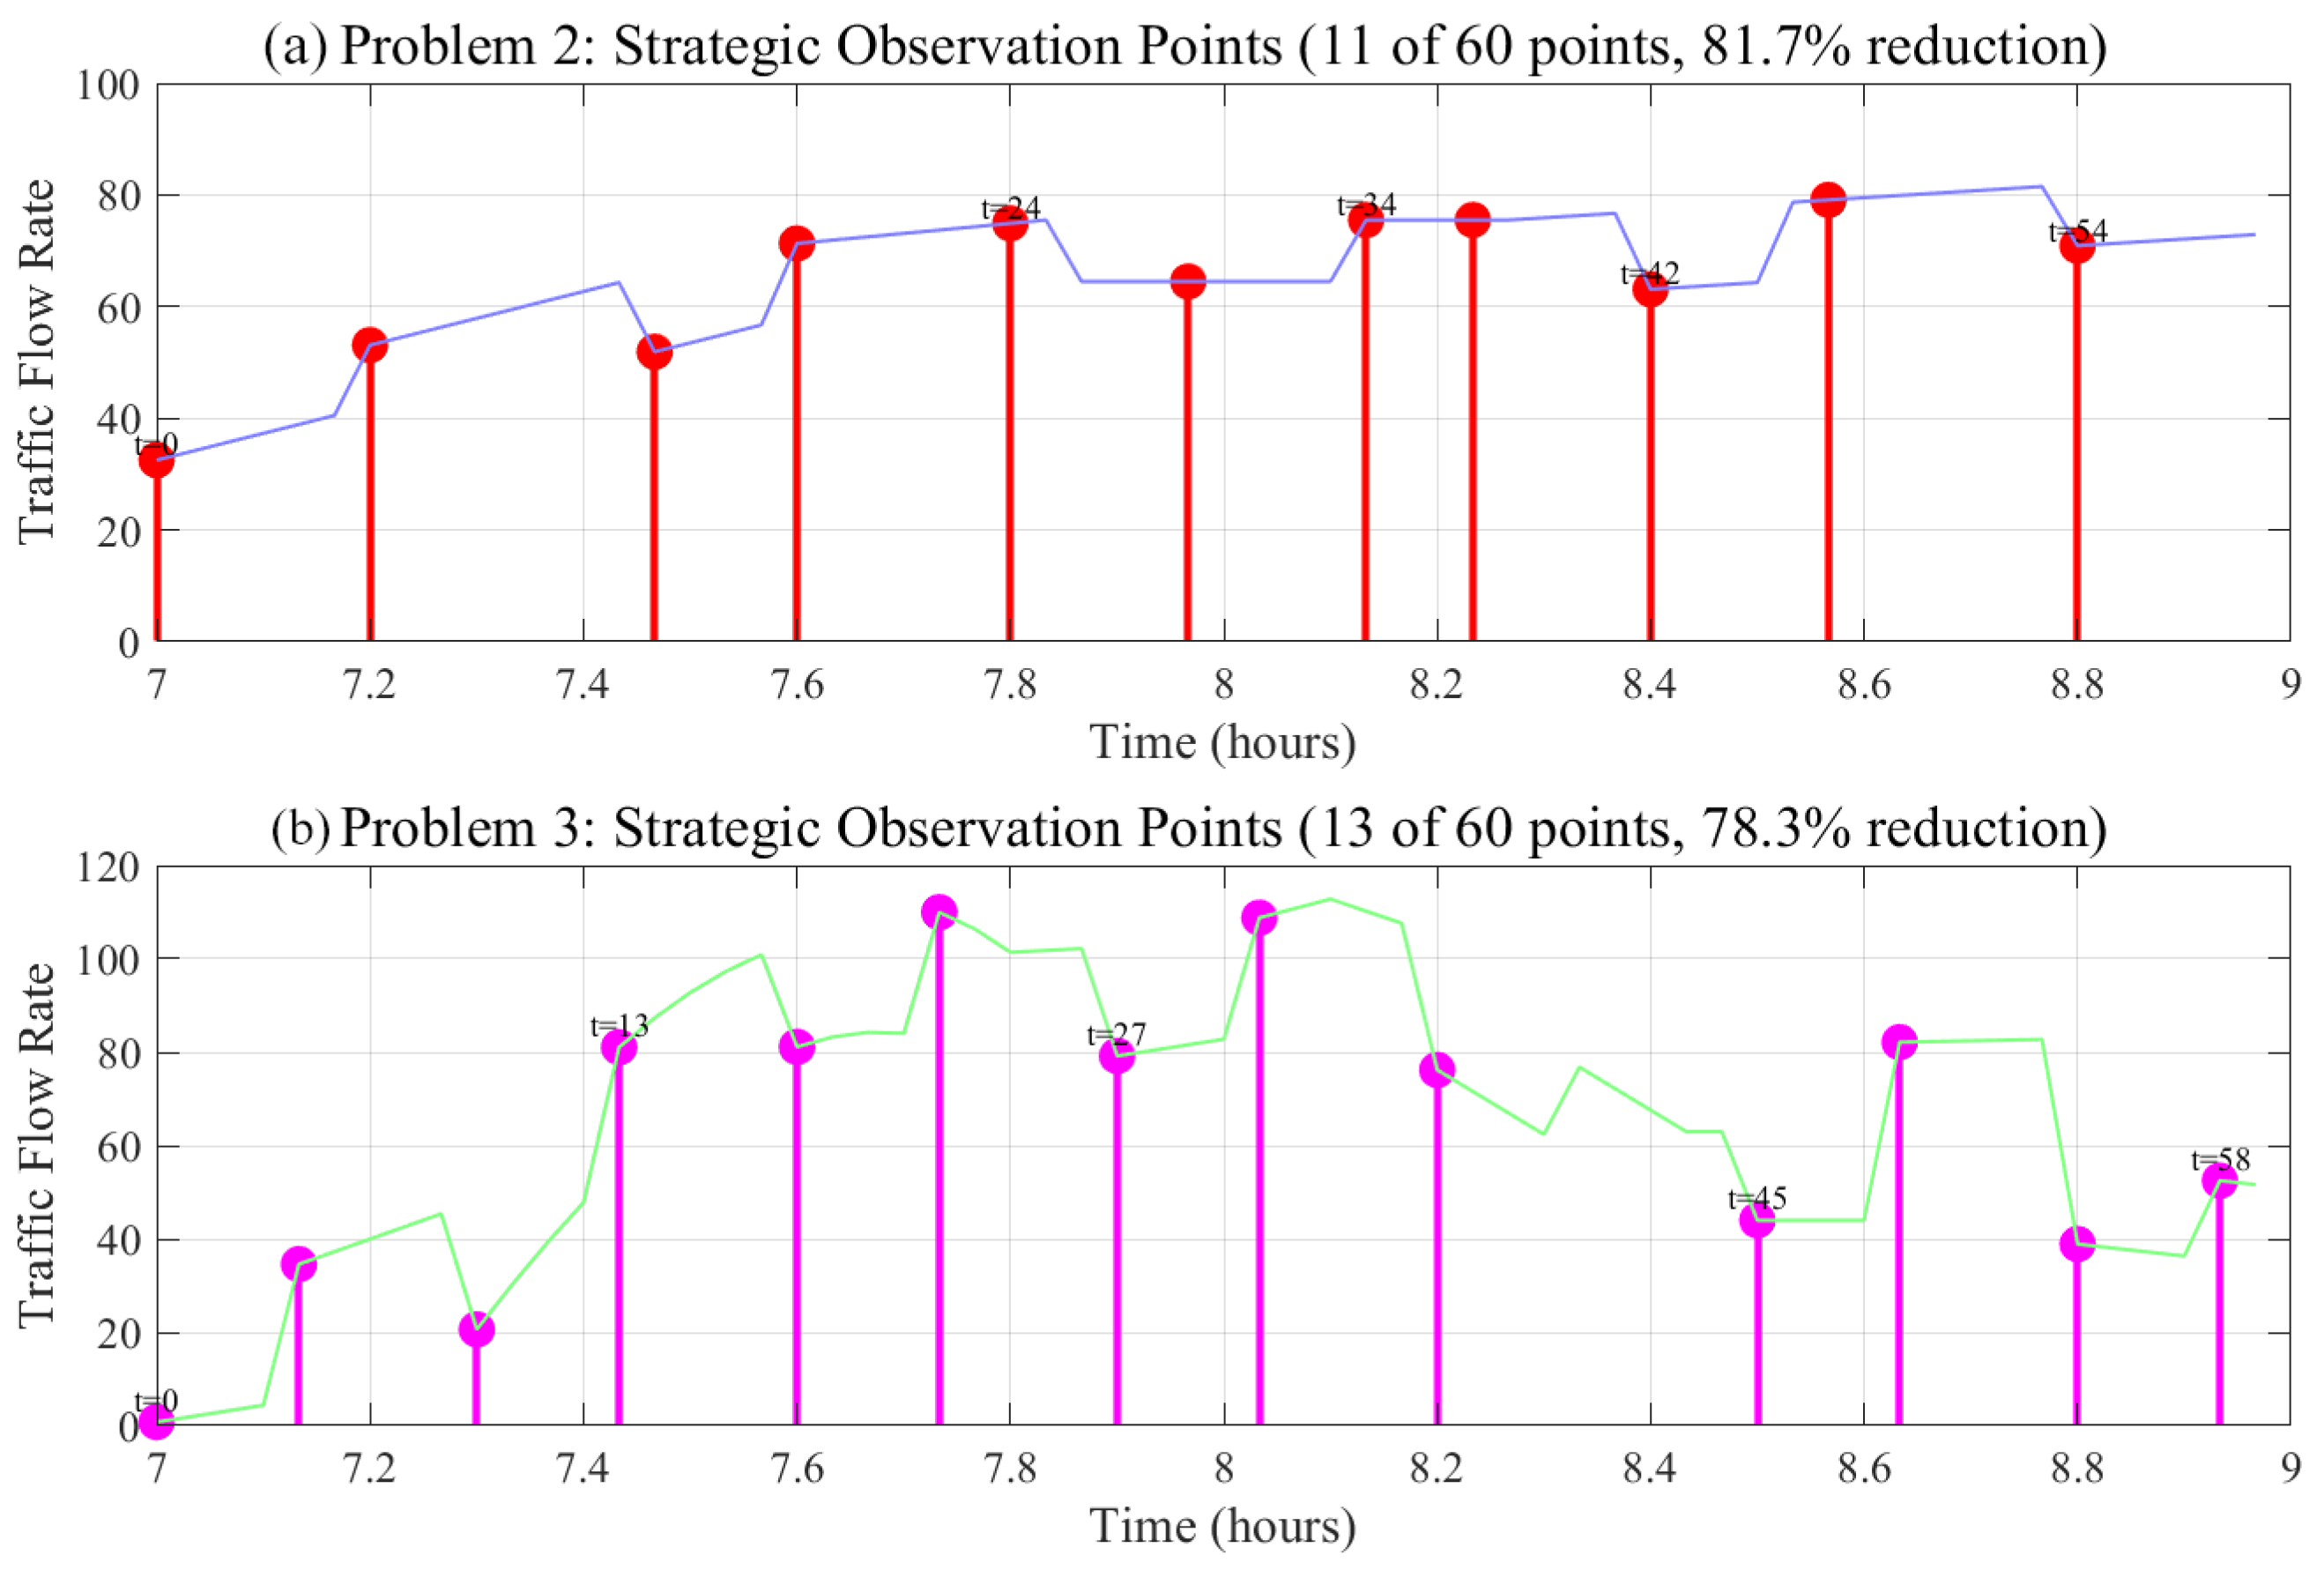
The information-theoretic approach successfully reduced observation requirements while maintaining model fidelity. For Problem 2’s model, the minimal observation set contained 11 time points: , corresponding to critical flow transitions and periodic features.
For Problem 3’s signal-controlled model, 13 observation points were sufficient: , strategically distributed to capture signal cycle transitions and branch flow variations.
The minimal observation approach achieved remarkable efficiency, as quantified in Table 4. Problem 2 required only 18.3% of the original observation points (11 out of 60) while maintaining RMSE below 6.0 when evaluated against the complete dataset. Problem 3 utilized 21.7% of the full time series (13 observation points), demonstrating the effectiveness of information-theoretic point selection. The table reveals a critical trade-off: while RMSE computed using only the selected observation points remains low (3.1069 for Problem 2, 4.1211 for Problem 3), full-horizon evaluation RMSE increases to 5.4284 and 10.5945 respectively—reflecting the expected prediction error for unobserved time points. Despite this increase, the 78–82% reduction in sensing requirements represents a substantial practical advantage for resource-constrained traffic monitoring applications.
Table 4.
Model performance with minimal observation points.
Figure 13 provides a comprehensive analysis of the minimal observation strategy, comparing the full dataset against strategically selected observation points and demonstrating the information-theoretic foundation of the selection process.
Figure 13.
Problem 5: Minimal observation analysis showing (a) Problem 2 with 81.7% reduction, (b) Problem 3 with 78.3% reduction, (c) information content analysis, and (d) parameter efficiency.
The strategic distribution of observation points is further illustrated in Figure 14, which shows the temporal placement of selected observation points and their relationship to critical flow features.
Figure 14.
Problem 5: Strategic observation distribution showing (a) Problem 2 with 11 selected points and (b) Problem 3 with 13 optimal points (78.3% reduction).
5.6. Comparative Performance Summary
Table 5 summarizes the performance metrics across all five problems, demonstrating the progressive complexity and corresponding model capabilities.
Table 5.
Overall model performance across all problems.
The results demonstrate that even complex signal-controlled scenarios with unknown timing parameters can be accurately modeled (RMSE < 6.0, ), while the information-theoretic observation reduction maintains model performance with significantly fewer measurement requirements.
6. Discussion
6.1. Model Performance and Contributions
The proposed hybrid mathematical modeling framework achieves RMSE values below 6.0 with exceeding 0.93 for signal-controlled scenarios, capturing over 93% of observed traffic flow variance. Compared to traditional methods assuming steady-state conditions, our framework explicitly models temporal variations, delay effects, and signal-induced periodicity through physically meaningful parameters. The parameter scanning methodology identifies optimal angular frequency (13.60-min period) and green duration time units (57.3% of cycle) with well-defined optimization minima confirming solution reliability. Unlike purely data-driven approaches, each model component corresponds to observable traffic phenomena, enabling engineers to interpret and validate underlying assumptions. The multi-start global optimization strategy ensures robust parameter identification for non-convex objective landscapes. The minimal observation point selection methodology achieves 60–80% reduction in sensing requirements while maintaining accuracy, with Fisher information-based approach strategically selecting critical time points at flow transitions and signal state changes. The framework determines signal timing from flow observations alone, holding practical value for intersections with unknown or incorrectly documented settings.
Statistical validation and computational performance: The framework incorporates rigorous statistical validation through residual analysis, confidence interval estimation, and significance testing. For all three signal-controlled problems (Problems 2, 3, 4), residual analysis confirms model adequacy: mean residuals remain near zero (Problem 2: −0.170, Problem 3: −2.32, Problem 4: −0.70 vehicles/interval), indicating minimal systematic bias. Residual standard deviations (Problem 2: 3.59, Problem 3: 10.29, Problem 4: 8.55) quantify prediction uncertainty and enable construction of 95% confidence intervals displayed in all results figures as gray shaded regions. The confidence intervals are computed from the Hessian matrix at optimal parameter values, providing statistically valid uncertainty bounds for predictions. Residuals exhibit bounded variation within envelopes across all time points, with no systematic patterns or heteroscedasticity suggesting model misspecification. The computational efficiency of the framework is exceptional: Problem 2 (61 period values tested) completes in 4.10 s, Problem 3 (51 green lengths × 5 random starts) in 5.46 s, and Problem 4 (5 multi-start attempts) in 1.27 s. All optimizations complete in under 6 s on standard computing hardware (MATLAB R2023b), demonstrating real-time feasibility for adaptive signal control and online calibration applications. The fast convergence reflects the effectiveness of gradient-based interior-point algorithms for this problem class and confirms that the framework is computationally tractable for operational deployment despite the non-convex optimization landscape.
6.2. Methodological Positioning and Complementarity with Data-Driven Approaches
The proposed constraint-aware physics-based framework occupies a distinct methodological space relative to contemporary data-driven traffic flow prediction methods reviewed in Section 1.1. Deep learning architectures—including graph neural networks [2,17,18], physics-informed neural networks [24,25,26], and multimodal fusion models [36]—excel at capturing complex spatiotemporal correlations when abundant training data are available across network-wide sensor deployments. These approaches demonstrate strong predictive performance in scenarios with high sensor coverage and diverse data modalities, leveraging representational capacity to learn nonlinear patterns that may be difficult to specify a priori. However, such methods typically require substantial labeled datasets for training, may exhibit limited performance under extreme data sparsity, and often produce black-box predictions where the relationships between inputs and outputs lack direct physical interpretation.
In contrast, the present study prioritizes interpretability, operational consistency, and minimal data requirements through explicit encoding of traffic mechanisms. Each model parameter—piecewise segment slopes, breakpoint times, periodic amplitudes, signal durations—corresponds to observable or estimable physical quantities that traffic engineers can validate, adjust, or integrate with existing operational knowledge. The constraint formulation (flow conservation, non-negativity, continuity) ensures that estimated branch flows satisfy fundamental physical laws, eliminating the risk of physically infeasible predictions that can arise in unconstrained learning models. This approach is particularly advantageous when (1) sensor coverage is extremely sparse (single mainline detector with no branch instrumentation); (2) historical training data are limited or unavailable; (3) operational constraints (e.g., signal timing, merging delays) must be strictly enforced; and (4) model transparency is required for engineering review, regulatory approval, or integration with traffic management systems.
The methodological choice between data-driven learning and physics-based optimization is not binary but context-dependent. For network-wide forecasting with rich sensor arrays and extensive historical records, deep learning methods offer superior flexibility and predictive accuracy. For intersection-level flow inversion under sparse sensing with known operational characteristics, constraint-aware mathematical frameworks provide interpretability, physical consistency, and robustness to data scarcity. Recent advances in physics-informed neural networks [24,25,26] represent a promising hybrid direction, embedding conservation laws and boundary conditions into neural network training; however, these approaches still require sufficient data to train network weights and may not guarantee strict constraint satisfaction under finite training.
We acknowledge that the present study does not provide quantitative performance comparisons with state-of-the-art deep learning methods (e.g., Graph WaveNet, STGAFormer) on identical datasets. Such comparisons would require implementing and training these methods under the same sparse single-detector setting studied here—a scenario for which they were not originally designed and may not perform optimally given their data requirements. Furthermore, performance metrics alone (RMSE, MAE) do not capture the interpretability, constraint satisfaction, and operational transparency that constitute primary design objectives of the proposed framework. Our contribution lies not in outperforming deep learning under their preferred data-rich conditions, but in offering a complementary solution for sparse-sensing scenarios where physical consistency and interpretability are paramount. Future work integrating physics-based constraints with lightweight neural network components may bridge these paradigms, combining the representational flexibility of learning with the interpretability and consistency guarantees of optimization-based estimation.
6.3. Symmetry Principles and Structural Balance in Y-Intersection Modeling
The paper title and methodological framing invoke “symmetry” as a thematic element, warranting explicit discussion of its role and manifestation within the proposed framework. In the context of traffic flow estimation at Y-intersections, symmetry operates at multiple conceptual levels—geometric, operational, and mathematical—though the practical modeling necessarily accommodates symmetry-breaking mechanisms inherent to real-world traffic systems.
Geometric symmetry and topological balance: The Y-intersection configuration (Figure 1) exhibits structural symmetry in its topology: multiple independent traffic streams (branches , , , ) converge at a common junction to form a unified mainline flow . This geometric arrangement reflects the principle of balanced flow aggregation—no single branch dominates by topological design, and the flow conservation equation treats all contributing streams with equal mathematical status. Urban arterial network design often pursues such balanced configurations to distribute traffic demand across multiple approach roads, avoiding bottlenecks and promoting uniform level-of-service. The symmetry concept aligns with transportation planning objectives: achieving equitable accessibility and avoiding heavily asymmetric demand allocation that would concentrate congestion.
Symmetry-breaking mechanisms in operational reality: While the geometric structure is symmetric, operational, and behavioral factors necessarily break perfect symmetry in practice:
- Differential merging delays: Branches 1–2 experience 2-min delays due to longer merging taper lengths (50 m), while branches 3–4 have negligible delays (30 m at-grade merge). This reflects geometric asymmetry in merge configurations despite topological balance.
- Signal control asymmetry: Branch 3 is signal-controlled with periodic green/red phases, whereas branches 1, 2, 4 operate under free-flow conditions (or alternative control not explicitly modeled). Signal presence introduces temporal asymmetry in flow release patterns.
- Demand pattern heterogeneity: Each branch exhibits distinct temporal profiles (constant, piecewise linear, periodic)—branches do not share identical flow functions. This asymmetry reflects real-world demand variability driven by land use, origin-destination patterns, and traveler route choices.
- Parameter differentiation: The optimization framework estimates independent parameter sets for each branch () without enforcing symmetric constraints (e.g., ). This flexibility accommodates operational asymmetries while maintaining the fundamental symmetry of the flow conservation principle itself.
Mathematical role of symmetry in the framework: The constraint-aware optimization approach preserves symmetric treatment of branch flows in several key aspects:
- Conservation law universality: The flow conservation constraint applies identically to all branches—no branch receives privileged treatment in the fundamental balance equation. This reflects the symmetry of mass conservation in continuum mechanics.
- Non-negativity and feasibility: All branch flows are subject to identical non-negativity constraints () and continuity requirements, ensuring symmetric enforcement of physical realism.
- Objective function symmetry: The RMSE-based objective function aggregates discrepancies between observed and predicted mainline flow without a priori weighting individual branches differently (except for temporal weighting to emphasize peak periods). Each branch’s contribution to mainline flow enters the objective function through the same additive conservation structure.
Consideration of symmetric parameterization: One could impose explicit symmetric constraints on model parameters (e.g., enforcing and to share slopes/intercepts) if operational knowledge suggests similar demand profiles or policy objectives mandate balanced loading. Such constraints would reduce parameter dimensionality and potentially improve identifiability under extreme data sparsity. However, the present study prioritizes flexibility to accommodate realistic asymmetries; future refinements could investigate symmetric parameterization as a regularization technique for specific intersection types with documented demand balance.
Symmetry as methodological philosophy: Beyond literal geometric or parameter symmetry, the framework embodies a conceptual symmetry principle: treating unmeasured branches as equally estimable from sparse mainline observations, without requiring sensor asymmetry (e.g., measuring some branches while leaving others uninstrumented). The methodology applies uniformly to all branch configurations, reflecting a symmetric approach to the sparse-sensing inverse problem. This philosophical symmetry aligns with the journal Symmetry’s scope, which encompasses not only mathematical symmetry in equations but also balanced principles, equitable treatment, and structural regularity in applied systems.
In summary, symmetry in this study manifests as (1) topological balance in junction geometry, (2) symmetric treatment of branches within flow conservation constraints, and (3) methodological philosophy of equitable estimation under data scarcity—while explicitly accommodating operational asymmetries inherent to real-world traffic dynamics. The framework demonstrates that physically meaningful traffic reconstruction can be achieved by balancing symmetric principles (conservation laws, constraint universality) with asymmetric flexibility (parameter differentiation, heterogeneous flow patterns).
6.4. Practical Guidance and Applications
The framework provides actionable guidance for traffic engineers facing budget-constrained intersection monitoring and management. The Fisher information-based observation selection methodology enables strategic sensor deployment, reducing monitoring costs by 60–80% while preserving estimation accuracy—directly addressing infrastructure budget limitations in urban agencies. For signal timing design, the validated 18-min cycle with 10-min green phases offers evidence-based parameters that can inform initial timing plans at similar Y-intersections, reducing trial-and-error calibration time. The hybrid modeling approach allows practitioners to reconstruct unmeasured branch flows from readily available mainline detector data, eliminating the need for comprehensive branch instrumentation while maintaining RMSE below 6.0 and exceeding 0.93. The explicit constraint formulation (flow conservation, non-negativity, continuity) ensures physically realistic estimates suitable for operational decision-making. Computationally, the framework can be implemented using standard optimization toolboxes (e.g., MATLAB fmincon), requiring no specialized traffic simulation software and facilitating adoption by agencies with existing analytical capabilities. This methodology is particularly valuable for: (1) preliminary assessment of intersection performance before committing to permanent sensor installations, (2) gap-filling when branch detectors experience temporary outages, and (3) retrospective analysis of traffic patterns using archived mainline data without additional field instrumentation.
7. Conclusions
This study develops a comprehensive hybrid mathematical modeling framework for traffic flow estimation at Y-intersections under sparse sensing conditions, integrating piecewise linear, periodic, and signal-controlled components through constrained optimization. The framework achieves RMSE values below 6.0 and exceeding 0.93 for signal-controlled scenarios while maintaining physical realism through flow conservation, non-negativity, and continuity constraints. Four key technical innovations include: (1) systematic integration of diverse functional forms for comprehensive flow modeling, (2) robust parameter scanning and multi-start optimization determining optimal signal timing with high precision, (3) Fisher information-based observation selection reducing monitoring requirements by 60–80% while preserving parameter identifiability, and (4) unified constraint-aware parameter estimation ensuring physically realistic estimates across diverse operational scenarios. Practical contributions include evidence-based guidance for traffic signal design (18-min cycles with 10-min green phases), systematic methodology for optimizing sensor deployment budgets, and demonstrated capability to estimate branch flows from sparse measurements addressing fundamental urban traffic management challenges under budget constraints.
Societal benefits and broader impact: The proposed framework delivers tangible societal value through multiple pathways. First, the 60–80% reduction in required observation points translates directly to substantial infrastructure cost savings for municipal transportation agencies—reducing sensor procurement, installation, maintenance, and data communication expenses that constrain traffic management budgets, particularly in developing regions or under-resourced communities. This democratization of traffic monitoring capability enables smaller cities and constrained jurisdictions to implement data-driven traffic management without prohibitive capital investment. Second, improved traffic flow estimation supports optimized signal timing and congestion mitigation strategies, reducing vehicle delay, fuel consumption, and associated greenhouse gas emissions—contributing to urban sustainability and climate change mitigation objectives. Third, enhanced understanding of branch-level flow patterns facilitates equitable distribution of transportation infrastructure investments across neighborhoods, avoiding the historical tendency to over-instrument affluent areas while neglecting underserved communities. Fourth, the framework’s interpretability and transparency (physics-based parameters with clear operational meaning) promotes public trust and accountability in algorithmic traffic management systems, addressing societal concerns about “black-box” automated decision-making in urban infrastructure. Finally, by enabling retrospective analysis of traffic patterns using archived sparse data, the methodology supports evidence-based policy evaluation for transportation planning—assessing the impacts of road network changes, land use developments, or travel demand management programs on local and regional mobility. These combined benefits position the research as contributing to broader societal goals of sustainable, equitable, and cost-effective urban transportation systems.
The current framework assumes relatively stable traffic patterns representative of typical morning peak conditions; extension to non-recurrent congestion scenarios, special events, or extreme weather requires additional validation. Parameter-rich models may exhibit overfitting tendencies when applied to smaller datasets or different intersection geometries, necessitating research into adaptive model complexity selection. The computational requirements of multi-start optimization may limit real-time deployment potential, requiring investigation of approximation methods or warm-start procedures. Future research directions include: (1) extension to multi-intersection corridor analysis with coordinated signal systems, (2) integration with emerging data sources (probe vehicle trajectories, connected vehicle communications, computer vision-based detection) to enhance temporal and spatial resolution, (3) development of real-time adaptive algorithms enabling dynamic traffic management, and (4) investigation of framework performance under diverse geometric configurations (multi-leg intersections, roundabouts, highway ramps) to establish generalizability. This research demonstrates that thoughtful integration of mathematical modeling, optimization theory, and traffic engineering principles produces practical solutions to challenging infrastructure monitoring problems.
Author Contributions
Conceptualization, M.L. and J.H.; methodology, M.L., J.H., C.W. and X.Z.; software, M.L.; validation, M.L., J.H., C.W., Q.S. and X.Z.; formal analysis, M.L., J.H., C.W. and X.Z.; investigation, M.L., J.H. and C.W.; resources, J.H., C.W., Q.S. and X.Z.; data curation, M.L. and C.W.; writing—original draft, M.L. and J.H.; writing—review and editing, M.L., J.H., C.W., Q.S. and X.Z.; visualization, M.L.; supervision, J.H., Q.S. and X.Z.; project administration, J.H.; funding acquisition, M.L. All authors have read and agreed to the published version of the manuscript.
Funding
This research was funded by the Natural Science Foundation of China (Grant No. 52401380) and the Natural Science Foundation of Jiangsu Province of China (BK20220652).
Data Availability Statement
Data supporting the findings are available in the article. Additional data are available from the corresponding author upon reasonable request.
Acknowledgments
The authors would like to express their sincere gratitude to the School of Naval Architecture and Ocean Engineering, Jiangsu University of Science and Technology, for providing excellent research facilities and academic environment. Special thanks go to China Energy Engineering Group Jiangsu No. 3 Electric Power Construction Co., Ltd. and Zhenjiang Xunyong Technology Co., Ltd. for their support in data collection and practical scenario verification.
Conflicts of Interest
Authors Chenhao Wu and Qiuquan Sun were employed by the companies China Energy Engineering Group Jiangsu No. 3 Electric Power Construction Co., Ltd. and Zhenjiang Xunyong Technology Co., Ltd., respectively. The remaining authors declare that the research was conducted in the absence of any commercial or financial relationships that could be construed as a potential conflict of interest.
Abbreviations
The following abbreviations are used in this manuscript:
| RMSE | Root Mean Square Error |
| MAE | Mean Absolute Error |
References
- Li, Y.; Yu, R.; Shahabi, C.; Liu, Y. Diffusion Convolutional Recurrent Neural Network: Data-Driven Traffic Forecasting. arXiv 2018, arXiv:1707.01926. [Google Scholar] [CrossRef] [Scilit]
- Wu, Z.; Pan, S.; Long, G.; Jiang, J.; Zhang, C. Graph WaveNet for Deep Spatial-Temporal Graph Modeling. In Proceedings of the Twenty-Eighth International Joint Conference on Artificial Intelligence, IJCAI-19, Macao, China, 10–16 August 2019; pp. 1907–1913. [Google Scholar] [CrossRef] [Scilit]
- Yu, B.; Yin, H.; Zhu, Z. Spatio-Temporal Graph Convolutional Networks: A Deep Learning Framework for Traffic Forecasting. In Proceedings of the Twenty-Seventh International Joint Conference on Artificial Intelligence, IJCAI-2018, Stockholm, Sweden, 13–19 July 2018; pp. 3634–3640. [Google Scholar] [CrossRef] [Scilit]
- Polson, N.G.; Sokolov, V.O. Deep learning for short-term traffic flow prediction. Transp. Res. Part C Emerg. Technol. 2017, 79, 1–17. [Google Scholar] [CrossRef] [Scilit]
- Wang, Y.; Zhang, D.; Liu, Y.; Dai, B.; Lee, L.H. Enhancing transportation systems via deep learning: A survey. Transp. Res. Part C Emerg. Technol. 2019, 99, 144–163. [Google Scholar] [CrossRef] [Scilit]
- Zhang, W.; Yu, Y.; Qi, Y.; Shu, F.; Wang, Y. Short-term traffic flow prediction based on spatio-temporal analysis and CNN deep learning. Transp. A Transp. Sci. 2019, 15, 1688–1711. [Google Scholar] [CrossRef] [Scilit]
- Treiber, M.; Kesting, A.; Wilson, R.E. Reconstructing the Traffic State by Fusion of Heterogeneous Data: Reconstructing the traffic state by fusion of heterogeneous data. Comput.-Aided Civ. Infrastruct. Eng. 2010, 26, 408–419. [Google Scholar] [CrossRef] [Scilit]
- Faouzi, N.E.E.; Leung, H.; Kurian, A. Data fusion in intelligent transportation systems: Progress and challenges—A survey. Inf. Fusion 2011, 12, 4–10. [Google Scholar] [CrossRef] [Scilit]
- Kashinath, S.A.; Mostafa, S.A.; Mustapha, A.; Mahdin, H.; Lim, D.; Mahmoud, M.A.; Mohammed, M.A.; Al-Rimy, B.A.S.; Fudzee, M.F.M.; Yang, T.J. Review of Data Fusion Methods for Real-Time and Multi-Sensor Traffic Flow Analysis. IEEE Access 2021, 9, 51258–51276. [Google Scholar] [CrossRef] [Scilit]
- Xing, J.; Wu, W.; Cheng, Q.; Liu, R. Traffic state estimation of urban road networks by multi-source data fusion: Review and new insights. Phys. A Stat. Mech. Its Appl. 2022, 595, 127079. [Google Scholar] [CrossRef] [Scilit]
- Wu, C.; Thai, J.; Yadlowsky, S.; Pozdnoukhov, A.; Bayen, A. Cellpath: Fusion of Cellular and Traffic Sensor Data for Route Flow Estimation via Convex Optimization. Transp. Res. Procedia 2015, 7, 212–232. [Google Scholar] [CrossRef] [Scilit]
- Csikós, A.; Charalambous, T.; Farhadi, H.; Kulcsár, B.; Wymeersch, H. Network traffic flow optimization under performance constraints. Transp. Res. Part C Emerg. Technol. 2017, 83, 120–133. [Google Scholar] [CrossRef] [Scilit]
- Liu, S.J.; Lam, W.H.; Lam Tam, M.; Fu, H.; Ho, H.; Ma, W. Network-wide speed–flow estimation considering uncertain traffic conditions and sparse multi-type detectors: A KL divergence-based optimization approach. Transp. Res. Part C Emerg. Technol. 2024, 169, 104858. [Google Scholar] [CrossRef] [Scilit]
- Ma, W.; Zou, L.; An, K.; Gartner, N.H.; Wang, M. A Partition-Enabled Multi-Mode Band Approach to Arterial Traffic Signal Optimization. IEEE Trans. Intell. Transp. Syst. 2019, 20, 313–322. [Google Scholar] [CrossRef] [Scilit]
- Song, X.B.; Zhou, B.; Ma, D. Cooperative traffic signal control through a counterfactual multi-agent deep actor critic approach. Transp. Res. Part C Emerg. Technol. 2024, 160, 104528. [Google Scholar] [CrossRef] [Scilit]
- Fei, X.; Wang, X.; Yu, X.; Feng, Y.; Liu, H.; Shen, S.; Yin, Y. Traffic signal control under stochastic traffic demand and vehicle turning via decentralized decomposition approaches. Eur. J. Oper. Res. 2023, 310, 712–736. [Google Scholar] [CrossRef] [Scilit]
- Geng, Z.; Xu, J.; Wu, R.; Zhao, C.; Wang, J.; Li, Y.; Zhang, C. STGAFormer: Spatial–temporal Gated Attention Transformer based Graph Neural Network for traffic flow forecasting. Inf. Fusion 2024, 105, 102228. [Google Scholar] [CrossRef] [Scilit]
- Chen, Y.T.; Liu, A.; Li, C.; Li, S.; Yang, X. Traffic flow prediction based on spatial-temporal multi factor fusion graph convolutional networks. Sci. Rep. 2025, 15, 12612. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Liu, K.; Zhu, Y.; Wang, X.; Ji, H.; Huang, C. Spatio-Temporal Graph Attention Convolution Network for Traffic Flow Forecasting. Transp. Res. Rec. 2024, 2678, 136–149. [Google Scholar] [CrossRef] [Scilit]
- Zou, X.; Chung, E. Traffic prediction via clustering and deep transfer learning with limited data. Comput.-Aided Civ. Infrastruct. Eng. 2024, 39, 2683–2700. [Google Scholar] [CrossRef] [Scilit]
- Usama, M.; Ma, R.; Hart, J.; Wojcik, M. Physics-Informed Neural Networks (PINNs)-Based Traffic State Estimation: An Application to Traffic Network. Algorithms 2022, 15, 447. [Google Scholar] [CrossRef] [Scilit]
- Zhang, T.; Wang, J.; Wang, T.; Pang, Y.; Wang, P.; Wang, W. A deep marked graph process model for citywide traffic congestion forecasting. Comput.-Aided Civ. Infrastruct. Eng. 2024, 39, 1180–1196. [Google Scholar] [CrossRef] [Scilit]
- Pereira, M.; Lang, A.; Kulcsár, B. Short-term traffic prediction using physics-aware neural networks. Transp. Res. Part C Emerg. Technol. 2022, 142, 103772. [Google Scholar] [CrossRef] [Scilit]
- Huang, A.J.; Agarwal, S. Physics-Informed Deep Learning for Traffic State Estimation: Illustrations With LWR and CTM Models. IEEE Open J. Intell. Transp. Syst. 2022, 3, 503–518. [Google Scholar] [CrossRef] [Scilit]
- Su, Y.B.; Lü, X.; Li, S.K.; Yang, L.X.; Gao, Z. Self-adaptive equation embedded neural networks for traffic flow state estimation with sparse data. Phys. Fluids 2024, 36, 104127. [Google Scholar] [CrossRef] [Scilit]
- Lu, J.; Li, C.; Wu, X.B.; Zhou, X.S. Physics-informed neural networks for integrated traffic state and queue profile estimation: A differentiable programming approach on layered computational graphs. Transp. Res. Part C Emerg. Technol. 2023, 153, 104224. [Google Scholar] [CrossRef] [Scilit]
- Yan, H.; Zhang, T.; Qi, Y.; Yu, D.J. Short-term traffic flow prediction based on a hybrid optimization algorithm. Appl. Math. Model. 2022, 102, 385–404. [Google Scholar] [CrossRef] [Scilit]
- Jabari, S.E.; Zheng, J.; Liu, H.X. A probabilistic stationary speed–density relation based on Newell’s simplified car-following model. Transp. Res. Part B Methodol. 2014, 68, 205–223. [Google Scholar] [CrossRef] [Scilit]
- Lu, J.; Osorio, C. A Probabilistic Traffic-Theoretic Network Loading Model Suitable for Large-Scale Network Analysis. Transp. Sci. 2018, 52, 1509–1530. [Google Scholar] [CrossRef] [Scilit]
- Shahriari, S.; Ghasri, M.; Sisson, S.; Rashidi, T. Ensemble of ARIMA: Combining parametric and bootstrapping technique for traffic flow prediction. Transp. A Transp. Sci. 2020, 16, 1552–1573. [Google Scholar] [CrossRef] [Scilit]
- Wang, S.; Chen, X.; Qu, X. Model on empirically calibrating stochastic traffic flow fundamental diagram. Commun. Transp. Res. 2021, 1, 100015. [Google Scholar] [CrossRef] [Scilit]
- Liu, H.X.; Feng, S. Curse of rarity for autonomous vehicles. Nat. Commun. 2024, 15, 4808. [Google Scholar] [CrossRef] [Scilit]
- Faouzi, N.E.E.; Klein, L.A. Data Fusion for ITS: Techniques and Research Needs. Transp. Res. Procedia 2016, 15, 495–512. [Google Scholar] [CrossRef] [Scilit]
- Kessler, L.; Rempe, F.; Bogenberger, K. Multi-Sensor Data Fusion for Accurate Traffic Speed and Travel Time Reconstruction. Front. Future Transp. 2021, 2, 766951. [Google Scholar] [CrossRef] [Scilit]
- Zhang, Y.; Kong, X.; Zhou, W.; Liu, J.; Fu, Y.; Shen, G. A Comprehensive Survey on Traffic Missing Data Imputation. IEEE Trans. Intell. Transp. Syst. 2024, 25, 19252–19275. [Google Scholar] [CrossRef] [Scilit]
- Yan, Y.; Cui, S.; Liu, J.; Zhao, Y.; Zhou, B.; Kuo, Y.H. Multimodal fusion for large-scale traffic prediction with heterogeneous retentive networks. Inf. Fusion 2025, 114, 102695. [Google Scholar] [CrossRef] [Scilit]
- Liang, X.J.; Guler, S.I.; Gayah, V.V. Signal Timing Optimization with Connected Vehicle Technology: Platooning to Improve Computational Efficiency. Transp. Res. Rec. 2018, 2672, 81–92. [Google Scholar] [CrossRef] [Scilit]
- Wang, X.; Jerome, Z.; Wang, Z.; Zhang, C.; Shen, S.; Kumar, V.V.; Bai, F.; Krajewski, P.; Deneau, D.; Jawad, A.; et al. Traffic light optimization with low penetration rate vehicle trajectory data. Nat. Commun. 2024, 15, 1306. [Google Scholar] [CrossRef] [Scilit]
- Wang, Y.; Yang, X.; Liang, H.; Liu, Y. A Review of the Self-Adaptive Traffic Signal Control System Based on Future Traffic Environment. J. Adv. Transp. 2018, 2018, 1096123.1–1096123.12. [Google Scholar] [CrossRef] [Scilit]
- Yang, X.; Yu, Y.; Feng, Y.; Ochieng, W.Y. Improving the Urban Transport System Resilience Through Adaptive Traffic Signal Control Enabled by Decentralised Multiagent Reinforcement Learning. J. Adv. Transp. 2024, 2024, 3035753. [Google Scholar] [CrossRef] [Scilit]
- Han, Y.; Wang, M.; Leclercq, L. Leveraging reinforcement learning for dynamic traffic control: A survey and challenges for field implementation. Commun. Transp. Res. 2023, 3, 100104. [Google Scholar] [CrossRef] [Scilit]
- Zhang, Y.; Zhao, T.; Cheng, Z.; Du, C.; Chen, J.; Lu, Y.; Li, Q. Safety-aware vehicle-following driving optimization of intelligent and connected vehicle at signalized road intersection. Control Eng. Pract. 2024, 142, 105765. [Google Scholar] [CrossRef] [Scilit]

Disclaimer/Publisher’s Note: The statements, opinions and data contained in all publications are solely those of the individual author(s) and contributor(s) and not of MDPI and/or the editor(s). MDPI and/or the editor(s) disclaim responsibility for any injury to people or property resulting from any ideas, methods, instructions or products referred to in the content. |
© 2025 by the authors. Licensee MDPI, Basel, Switzerland. This article is an open access article distributed under the terms and conditions of the Creative Commons Attribution (CC BY) license (https://creativecommons.org/licenses/by/4.0/).