


A Large-Scale 3D Gaussian Reconstruction Method for Optimized Adaptive Density Control in Training Resource Scheduling

Highlights
- A single-GPU large-scale 3D Gaussian Splatting (3DGS) framework is proposed, integrating content-adaptive KD-tree partitioning and auxiliary neighboring point clouds to mitigate boundary artifacts and missing supervision between subregions.
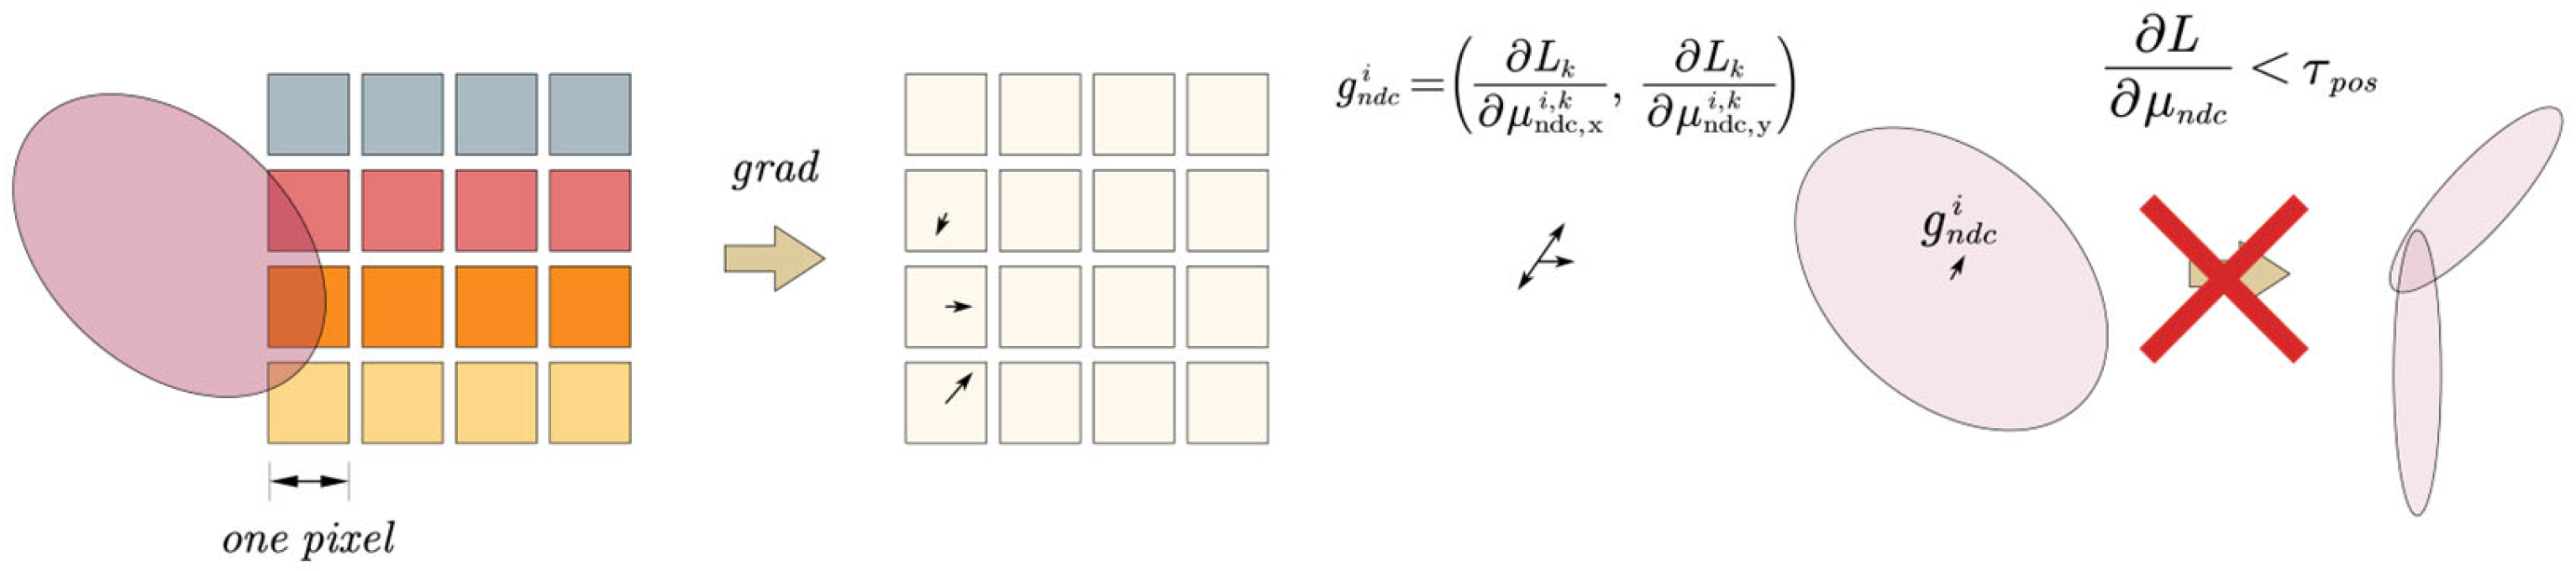
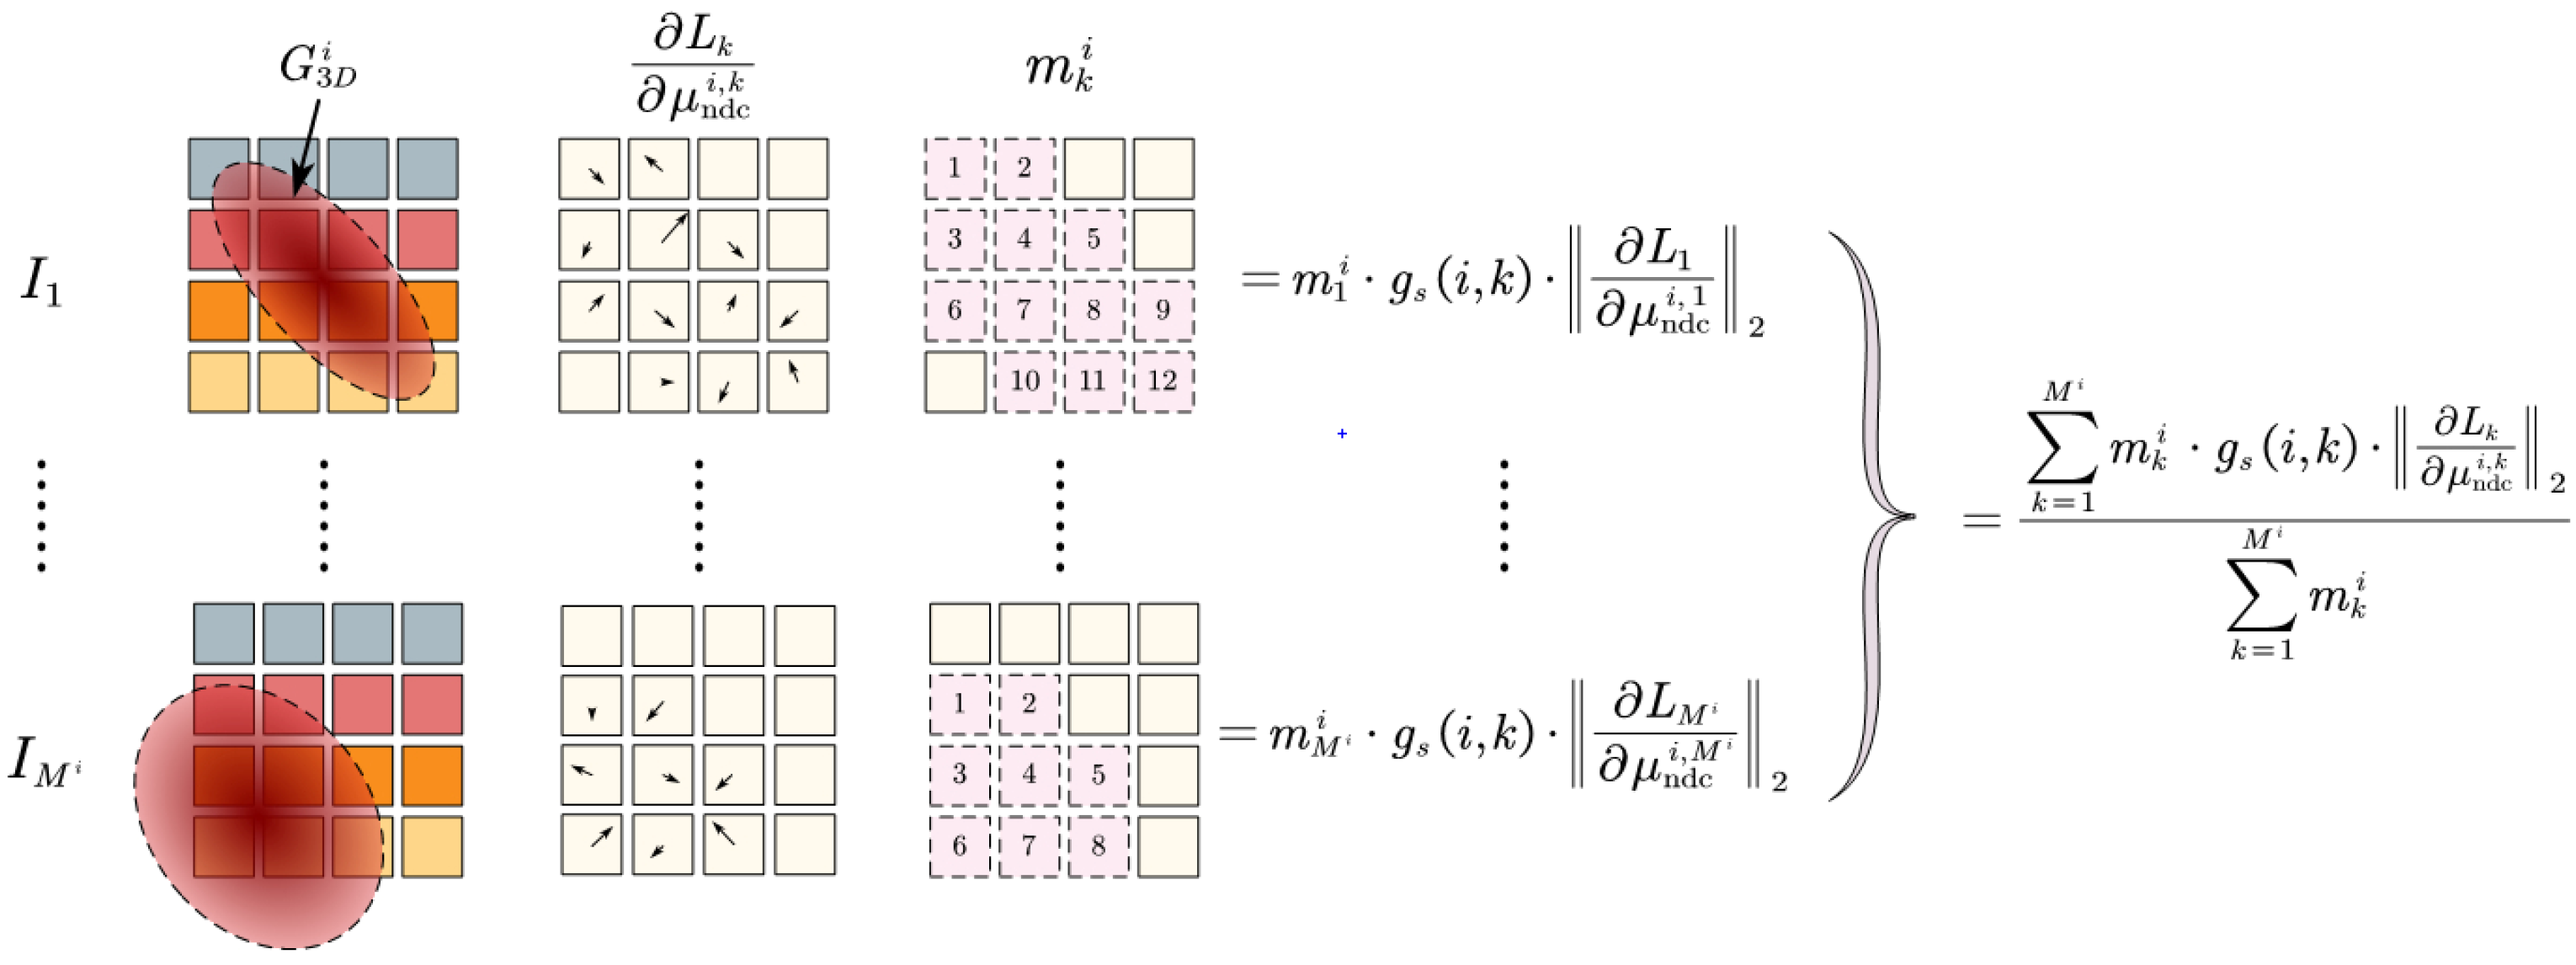
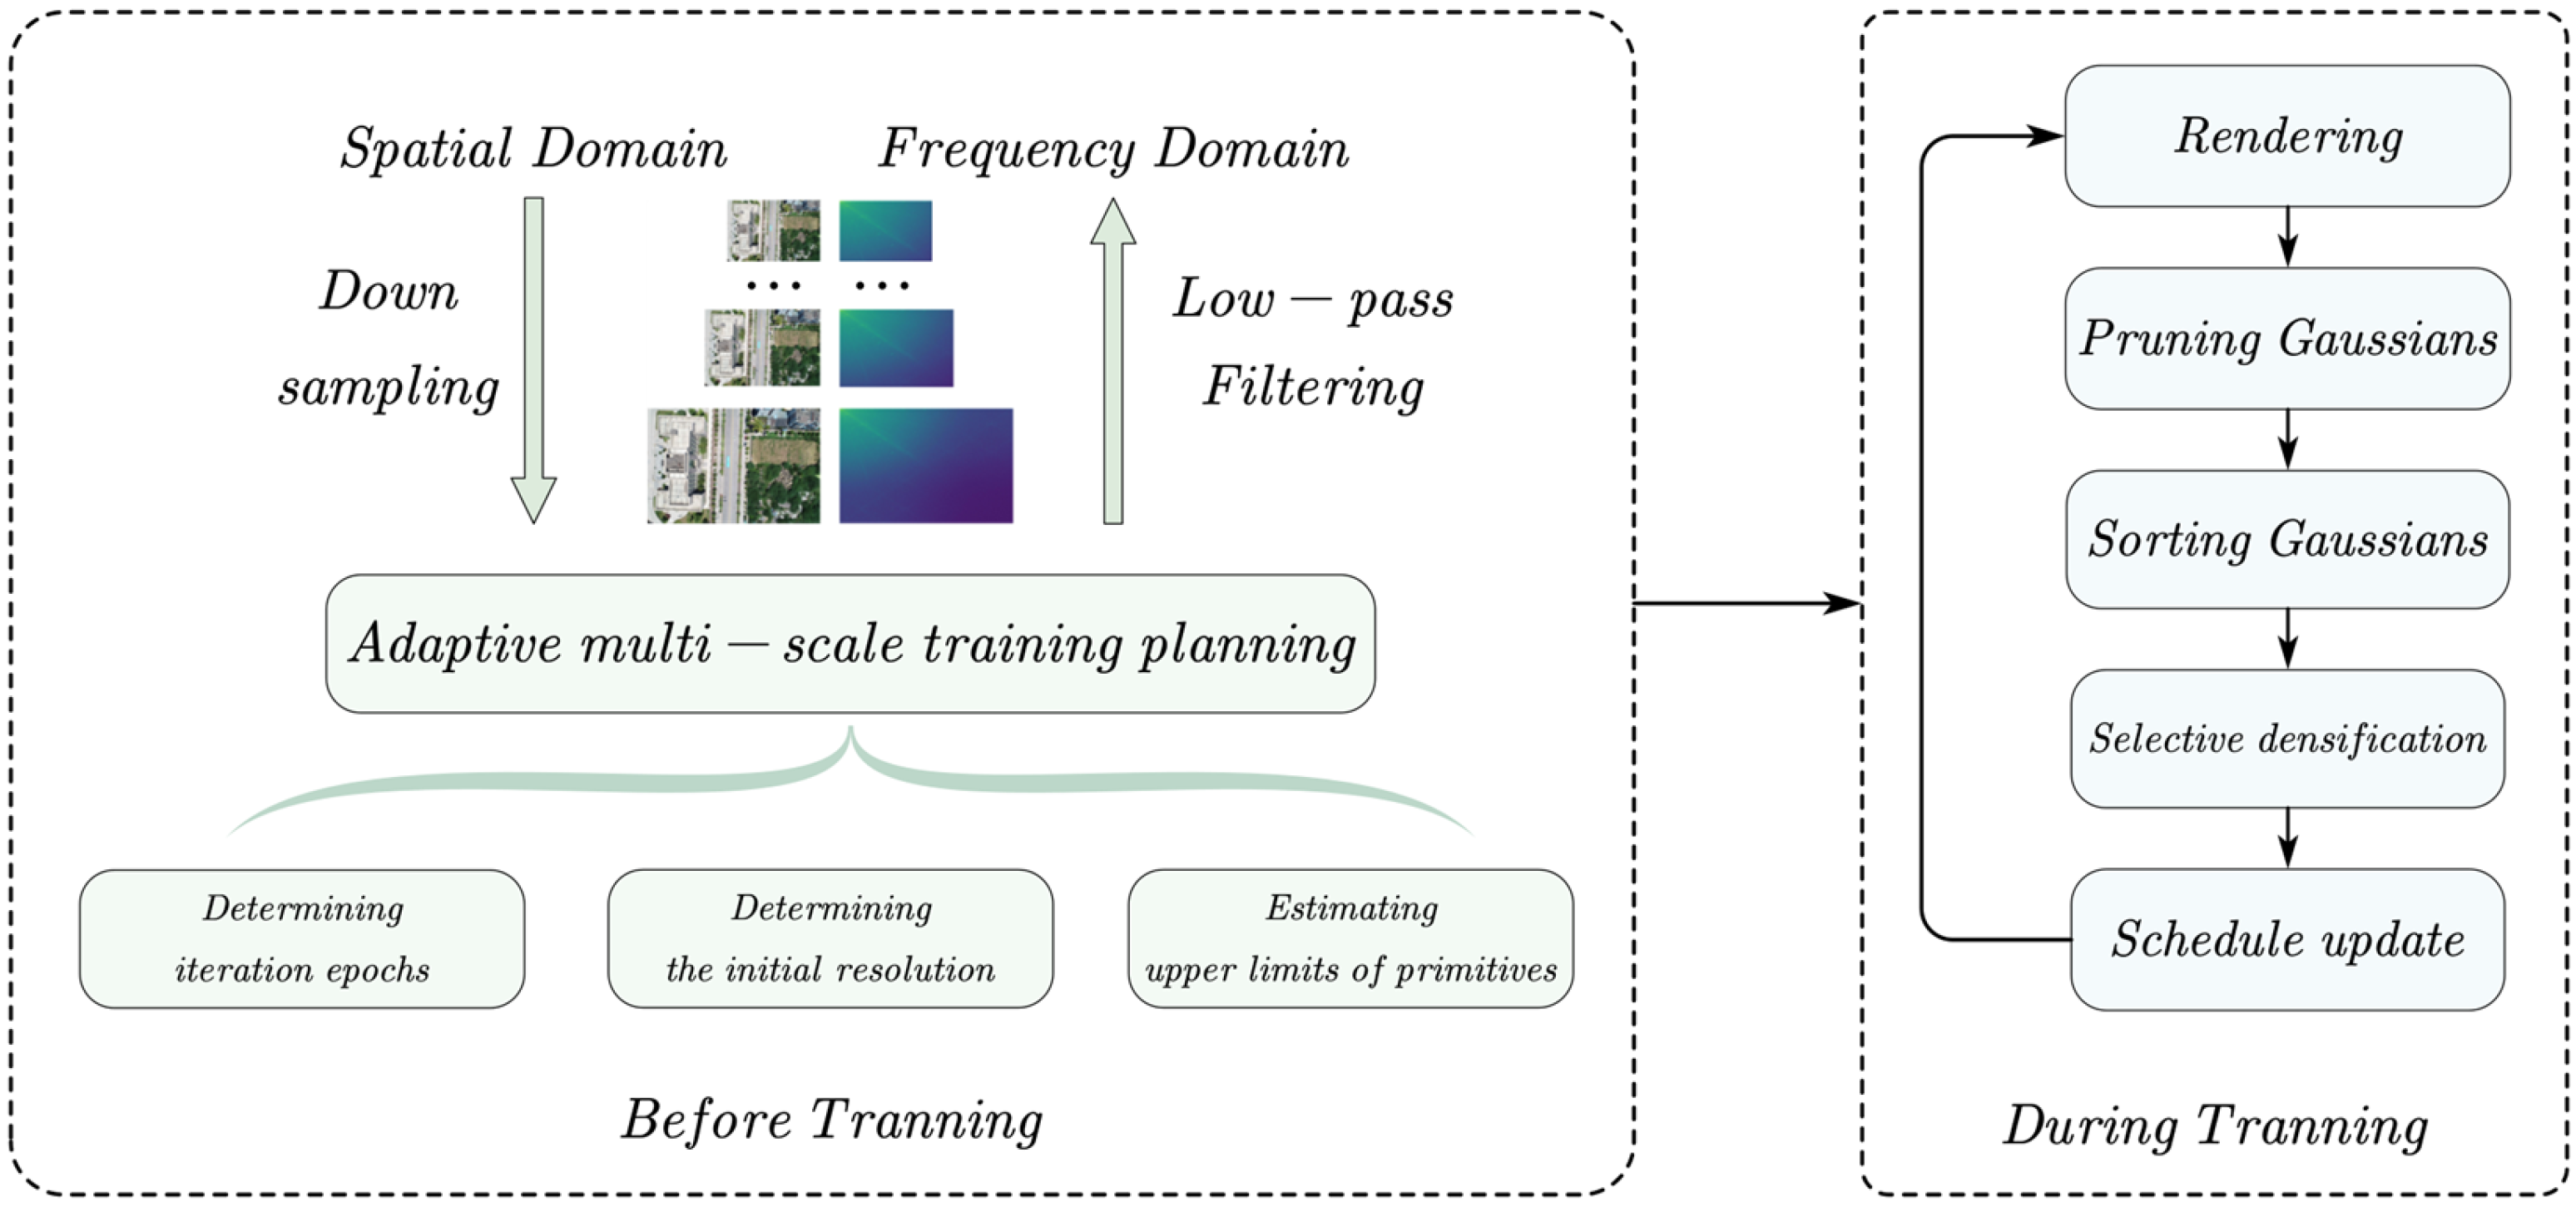
- An adaptive density control (ADC) method based on pixel-weighted gradient scaling, combined with a frequency-domain adaptive multi-scale training scheduler, achieves higher densification precision and significantly improved training efficiency.
- The framework substantially lowers hardware requirements, enabling practical 3DGS deployment in resource-constrained environments such as disaster response and urban digital twin applications.
- It establishes a generalizable paradigm for balanced scene partitioning and artifact-free densification, which can be integrated with compression or acceleration techniques to further reduce model size and computational costs.
Abstract
1. Introduction
2. Related Work
2.1. Neural Radiance Fields and 3DGS
2.2. Large-Scale Scene Reconstruction
2.3. Comparison with Existing Large-Scale 3DGS Frameworks
3. Preliminary
4. Methodology
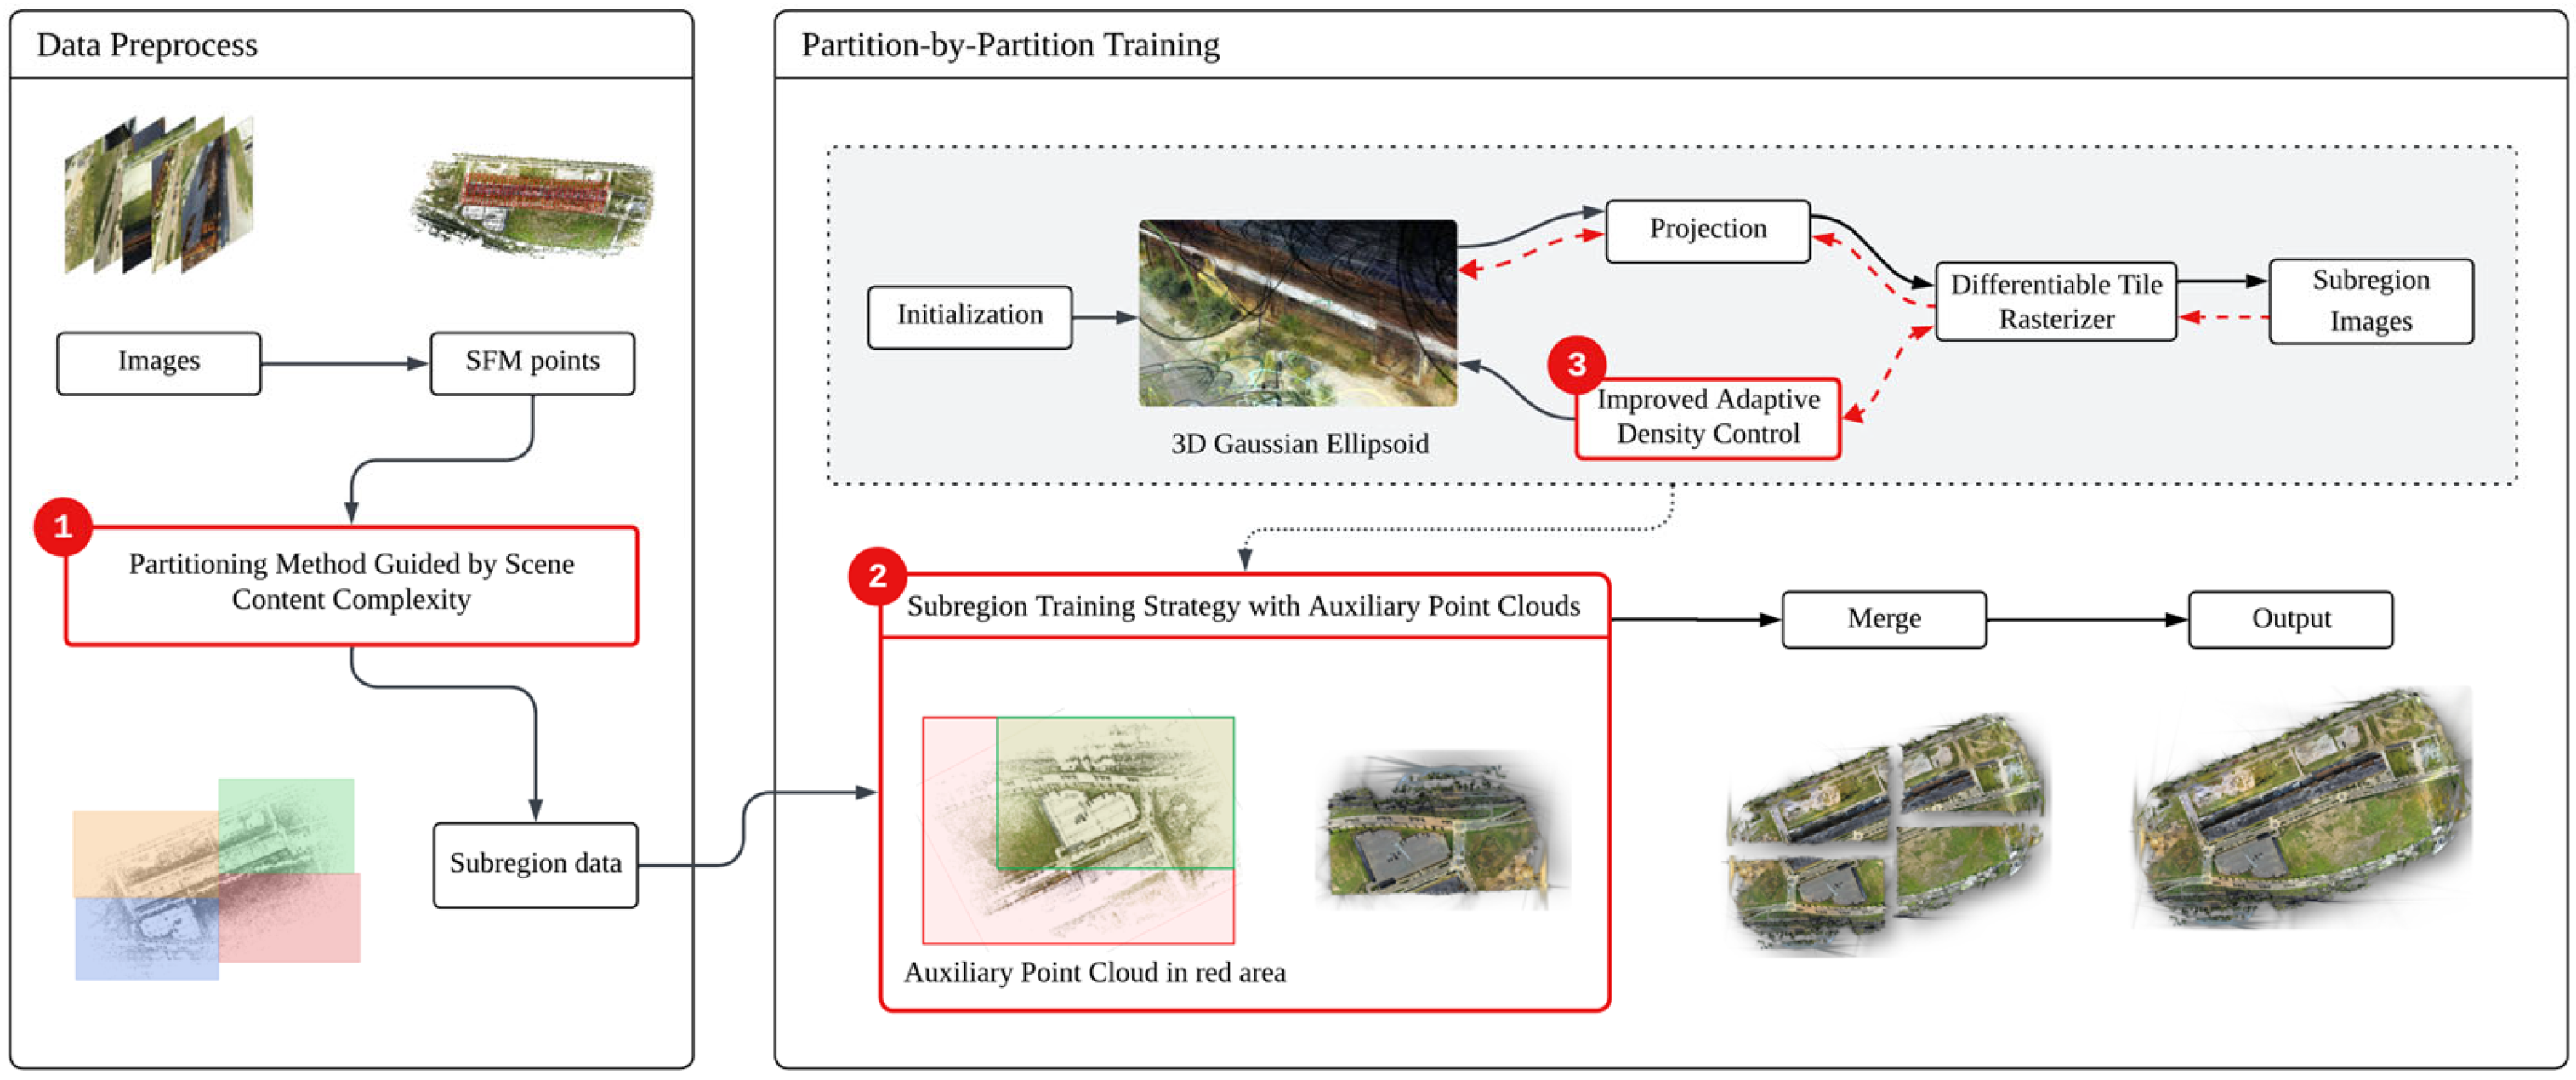
4.1. Overview
- Content-Adaptive Partition Training Strategy.
- 2.
- Improved Adaptive Densify Control Mechanism (Figure 1➂).
4.2. Content-Adaptive Partition Training Strategy
- Adaptive scene partitioning based on the spatial distribution of point clouds, ensuring complete scene coverage while reducing computational costs. Additionally, quantitative correlation analysis is employed to identify the most informative training images, improving efficiency and avoiding redundant computation.
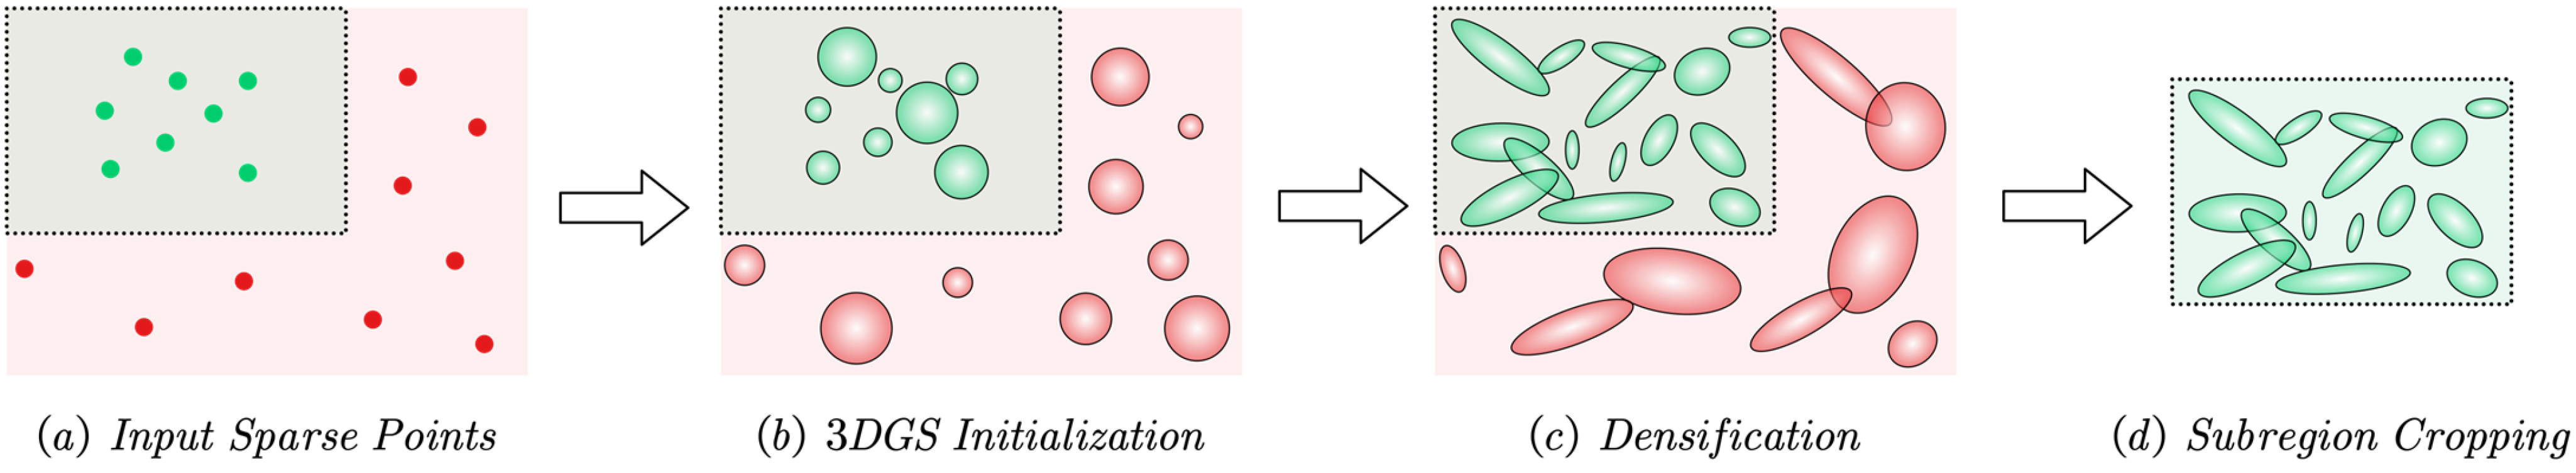
- Auxiliary supervision using external point clouds, which establishes a comprehensive supervisory framework to mitigate boundary noise caused by missing contextual information and to maintains global consistency in reconstruction accuracy.
4.2.1. Partitioning Method Guided by Scene Content Complexity
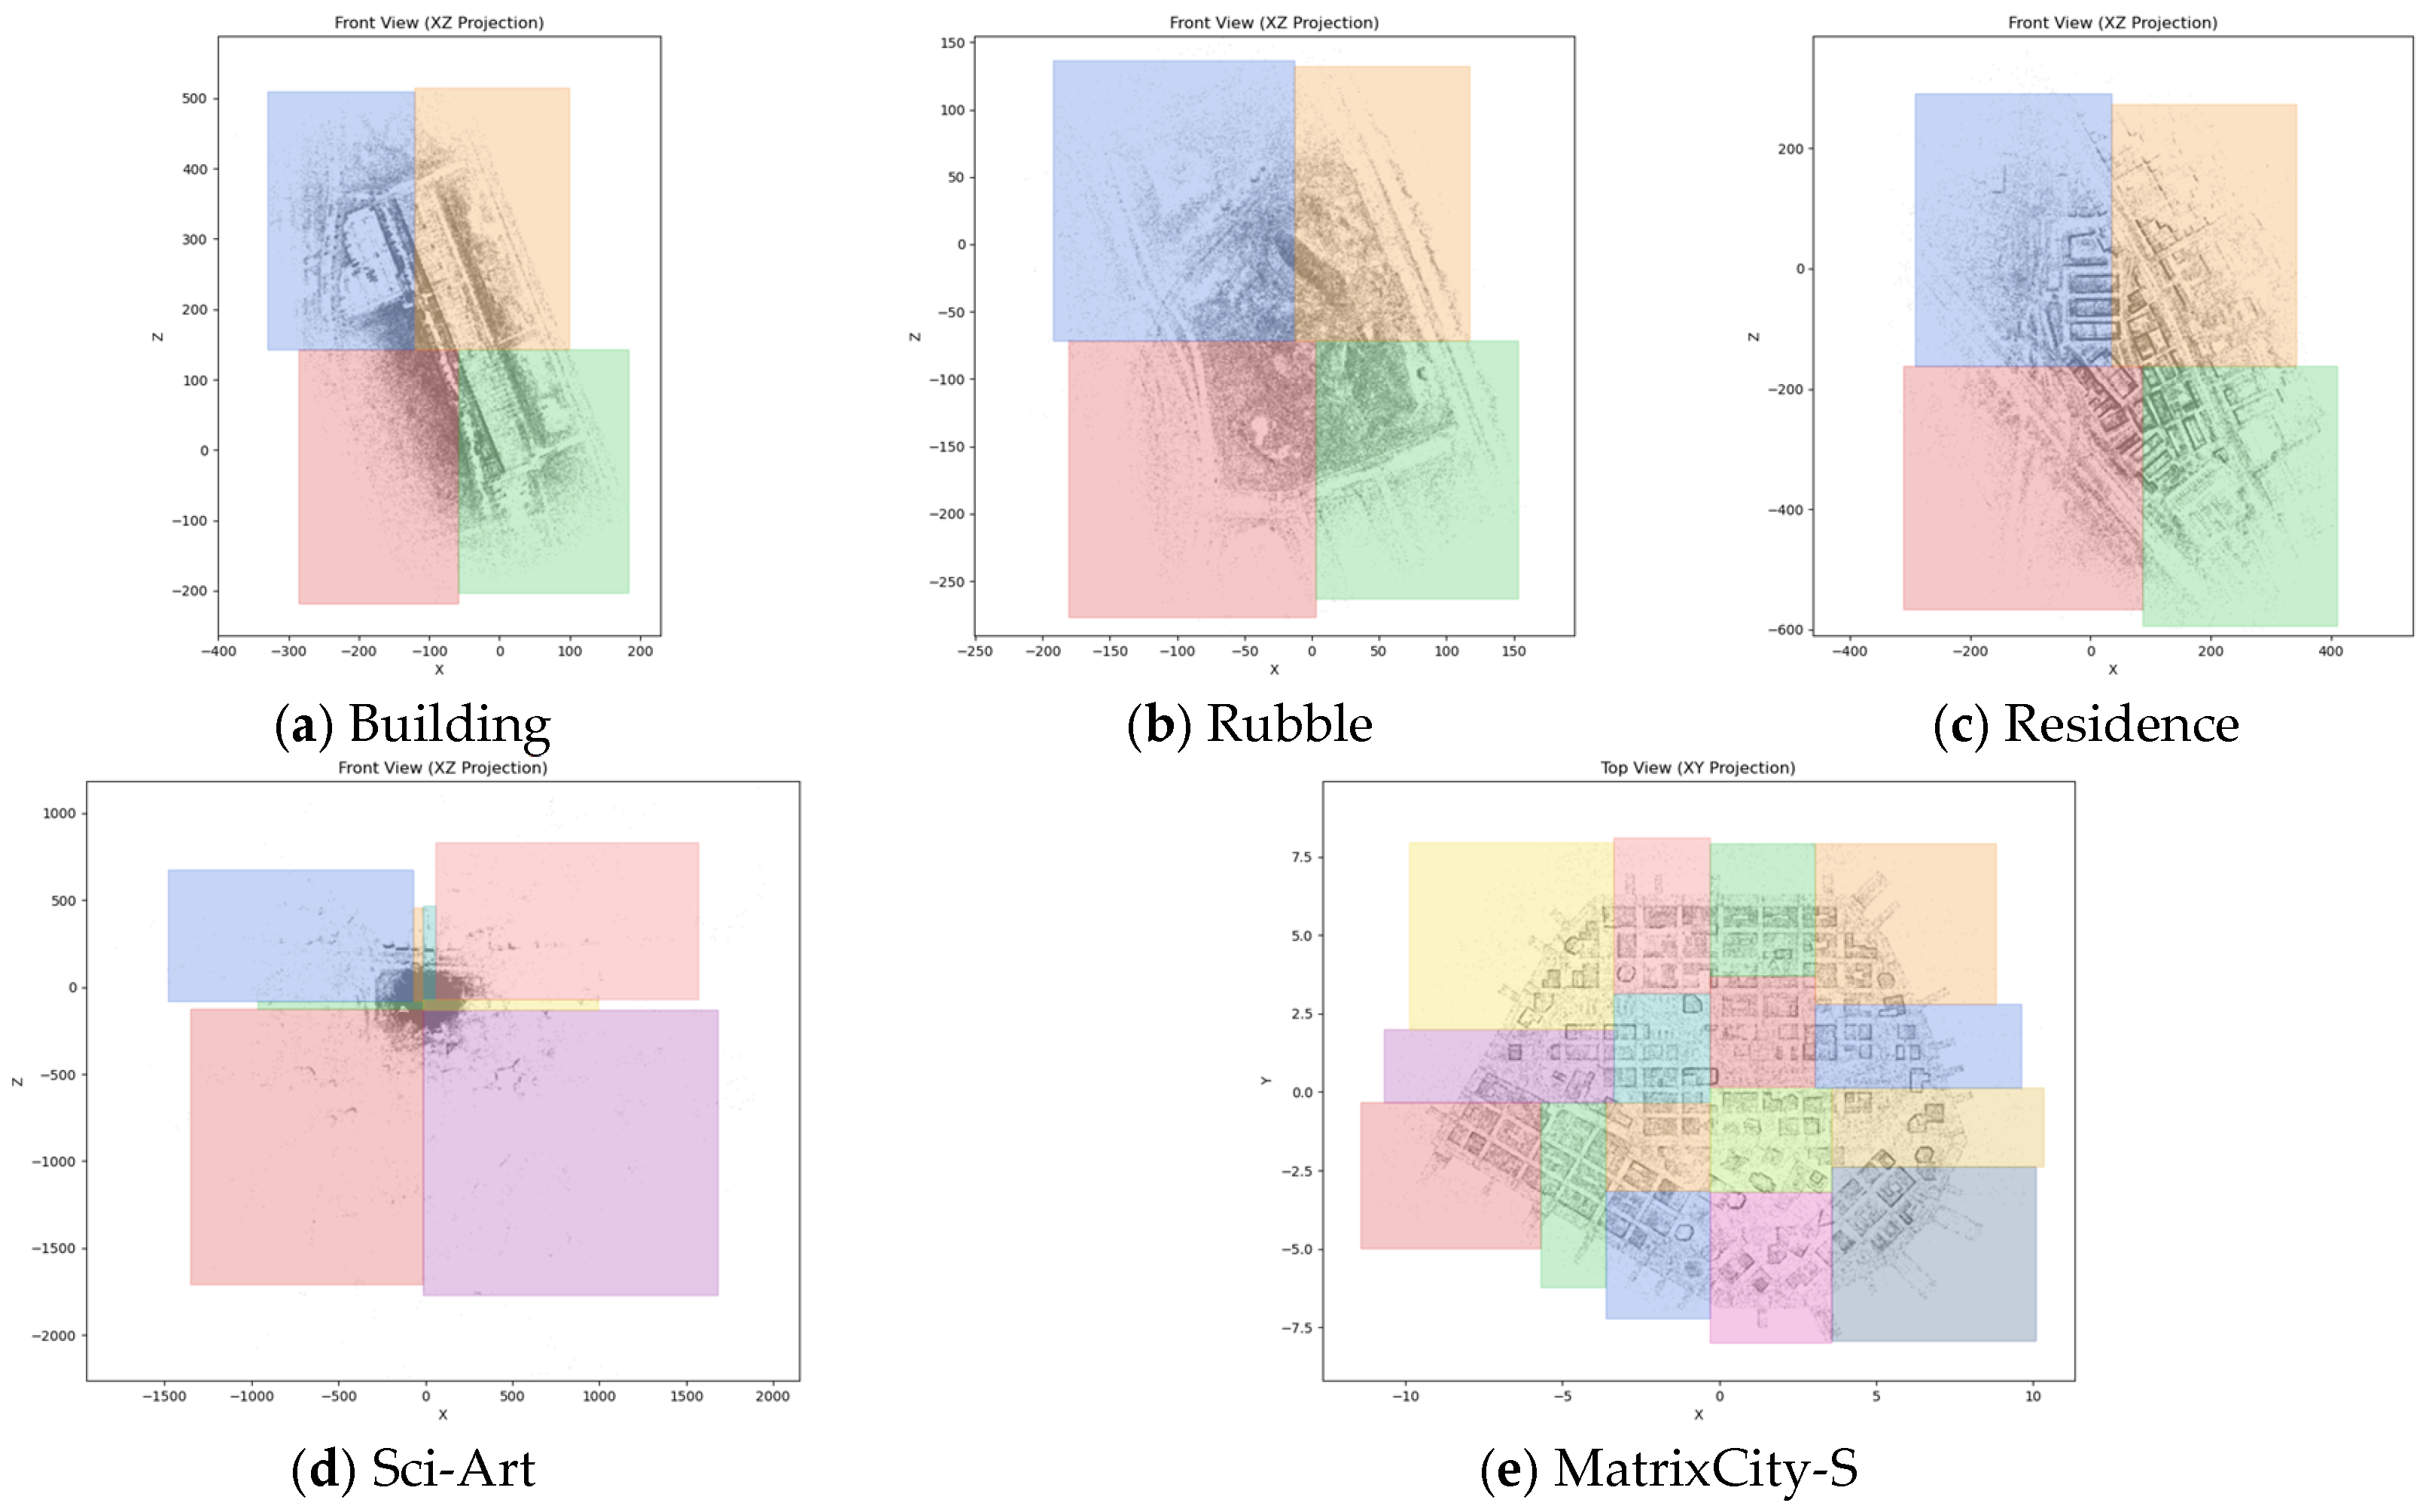
- Complexity-adaptive partitioning. Feature-rich areas are divided into denser subregions, while sparse regions are merged into larger ones.
- Balanced computational-load control. Point-cloud density and view-to-region correlation are quantified to ensure comparable computational demand across all subregions.
| Algorithm 1 Scene-content-complexity-guided spatial partitioning |
| Input: Sparse point cloud set where |
| Parameters: |
| : Maximum KD-tree depth |
| : Maximum number of points per leaf node |
| : View-to-subregion correlation threshold |
| Output: Training view sets for all subregions |
| 1: procedure NormalizeSceneCoordinates () |
| 2: Estimate ground normal using Manhattan-world assumption |
| 3: Align the normal with the z-axis |
| 4: Project onto the x-y plane, forming 2D point cloud |
| 5: Return |
| 6: end procedure |
| 7: procedure AdaptiveKDTreePartition () |
| 8: Initialize root node with point set and depth |
| 9: while and do |
| 10: Split along the axis with maximum point density |
| 11: Generate two child nodes at the median on this axis |
| 12: Set 5–10% overlap for adjacent subregions |
| 13: |
| 14: end while |
| 15: Form subregion set |
| 16: return |
| 17: end procedure |
| 18: procedure AssignViewsForSubregions () |
| 19: Initialize for all |
| 20: Compute : total number of points in each (including overlaps) |
| 21: for each view do |
| 22: for each subregion do |
| 23: Compute : number of points in that lie in |
| 24: |
| 25: if then |
| 26: |
| 27: end if |
| 28: end for |
| 29: end for |
| 30: return |
| 31: end procedure |
| 32: |
| 33: |
| 34: |
| 35: return |
4.2.2. Subregion Training Strategy with Auxiliary Point Clouds
4.3. Improved Adaptive Density Control Mechanism
4.3.1. Adaptive Density Control Based on Pixel-Weight Scaling
4.3.2. Adaptive Multi-Scale Training Scheduling Strategy
5. Experiments and Discussion
5.1. Datasets and Metrics
5.1.1. Datasets
5.1.2. Metrics
5.2. Training Details
5.3. Comparison with Other Methods
5.3.1. Quantitative and Visual Comparison of Different Methods
5.3.2. Efficiency and Consumption
5.4. Ablation Studies
5.4.1. Evaluation of the Content-Adaptive Partitioning Strategy
5.4.2. Quantitative Results of Partition Training
5.4.3. Evaluation of the Improved Adaptive Density Control
5.4.4. Qualitative Comparison
6. Conclusions
Supplementary Materials
Author Contributions
Funding
Data Availability Statement
Conflicts of Interest
References
- Kerbl, B.; Kopanas, G.; Leimkuehler, T.; Drettakis, G. 3D Gaussian Splatting for Real-Time Radiance Field Rendering. ACM Trans. Graph. 2023, 42, 1–14. [Google Scholar] [CrossRef] [Scilit]
- Mildenhall, B.; Srinivasan, P.P.; Tancik, M.; Barron, J.T.; Ramamoorthi, R.; Ng, R. NeRF: Representing Scenes as Neural Radiance Fields for View Synthesis. Commun. ACM 2021, 65, 99–106. [Google Scholar] [CrossRef] [Scilit]
- Liu, Y.; Luo, C.; Fan, L.; Wang, N.; Peng, J.; Zhang, Z. CityGaussian: Real-Time High-Quality Large-Scale Scene Rendering with Gaussians. In Proceedings of the Computer Vision—ECCV 2024, Milan, Italy, 29 September–04 October 2024; pp. 265–282. [Google Scholar]
- Turki, H.; Ramanan, D.; Satyanarayanan, M. Mega-NeRF: Scalable Construction of Large-Scale NeRFs for Virtual Fly-Throughs. In Proceedings of the 2022 IEEE/CVF Conference on Computer Vision and Pattern Recognition (CVPR), New Orleans, LA, USA, 18–24 June 2022; pp. 12912–12921. [Google Scholar]
- Lin, J.; Li, Z.; Tang, X.; Liu, J.; Liu, S.; Liu, J.; Lu, Y.; Wu, X.; Xu, S.; Yan, Y.; et al. VastGaussian: Vast 3D Gaussians for Large Scene Reconstruction. In Proceedings of the 2024 IEEE/CVF Conference on Computer Vision and Pattern Recognition (CVPR), Seattle, WA, USA, 16–22 June 2024; pp. 5166–5175. [Google Scholar]
- Kerbl, B.; Meuleman, A.; Kopanas, G.; Wimmer, M.; Lanvin, A.; Drettakis, G. A Hierarchical 3D Gaussian Representation for Real-Time Rendering of Very Large Datasets. ACM Trans. Graph. 2024, 43, 1–15. [Google Scholar] [CrossRef] [Scilit]
- Chen, J.; Ye, W.; Wang, Y.; Chen, D.; Huang, D.; Ouyang, W.; Zhang, G.; Qiao, Y.; He, T. GigaGS: Scaling up Planar-Based 3D Gaussians for Large Scene Surface Reconstruction. arXiv 2024, arXiv:2409.06685. [Google Scholar]
- Jiang, L.; Ren, K.; Yu, M.; Xu, L.; Dong, J.; Lu, T.; Zhao, F.; Lin, D.; Dai, B. Horizon-Gs: Unified 3D Gaussian Splatting for Large-Scale Aerial-To-Ground Scenes. In Proceedings of the 2025 IEEE/CVF Conference on Computer Vision and Pattern Recognition (CVPR), Nashville, TN, USA, 10–17 June 2025; pp. 26789–26799. [Google Scholar]
- Schonberger, J.L.; Frahm, J.-M. Structure-from-Motion Revisited. In Proceedings of the 2016 IEEE Conference on Computer Vision and Pattern Recognition (CVPR), Las Vegas, NV, USA, 27–30 June 2016; pp. 4104–4113. [Google Scholar]
- Cao, Z.; Guang, J.; Qianyi, Z.; Hu, Z.; Wu, S.; Liu, J. Survey of 3D Reconstruction Techniques Based on 3D Gaussian Splatting. Robot 2024, 46, 611–622. [Google Scholar] [CrossRef]
- Müller, T.; Evans, A.; Schied, C.; Keller, A. Instant Neural Graphics Primitives with a Multiresolution Hash Encoding. ACM Trans. Graph. 2022, 41, 1–15. [Google Scholar] [CrossRef] [Scilit]
- Hu, T.; Liu, S.; Chen, Y.; Shen, T.; Jia, J. EfficientNeRF—Efficient Neural Radiance Fields. In Proceedings of the 2022 IEEE/CVF Conference on Computer Vision and Pattern Recognition (CVPR), New Orleans, LA, USA, 18–24 June 2022; pp. 12892–12901. [Google Scholar]
- Barron, J.T.; Mildenhall, B.; Tancik, M.; Hedman, P.; Martin-Brualla, R.; Srinivasan, P.P. Mip-NeRF: A Multiscale Representation for Anti-Aliasing Neural Radiance Fields. In Proceedings of the 2021 IEEE/CVF International Conference on Computer Vision (ICCV), Montreal, QC, Canada, 10–17 October 2021; pp. 5835–5844. [Google Scholar]
- Liu, W.; Zheng, X.X.; Li, Y.; Al-Naffouri, T.Y.; Yu, J.; Lou, X. CoARF++: Content-Aware Radiance Field Aligning Model Complexity With Scene Intricacy. IEEE Trans. Vis. Comput. Graph. 2025, 31, 8187–8199. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Chen, Y.; Wu, Q.; Harandi, M.; Cai, J. How Far Can We Compress Instant-NGP-Based NeRF? In Proceedings of the 2024 IEEE/CVF Conference on Computer Vision and Pattern Recognition (CVPR), Seattle, WA, USA, 16–22 June 2024; pp. 20321–20330. [Google Scholar]
- Yan, Z.; Li, C.; Lee, G.H. OD-NeRF: Efficient Training of On-the-Fly Dynamic Neural Radiance Fields. In Proceedings of the 2025 International Conference on 3D Vision (3DV), Singapore, 25–28 March 2025; pp. 524–533. [Google Scholar]
- Li, Z.; Wang, Q.; Yue, H.; Nie, X. Toward Automatic 3D Model Reconstruction of Building Curtain Walls from UAV Images Based on NeRF and Deep Learning. Remote Sens. 2025, 17, 3368. [Google Scholar] [CrossRef] [Scilit]
- Li, L.; Zhang, Y.; Wang, Z.; Zhang, Z.; Jiang, Z.; Yu, Y.; Li, L.; Zhang, L. Shadow-Aware Point-Based Neural Radiance Fields for High-Resolution Remote Sensing Novel View Synthesis. Remote Sens. 2024, 16, 1341. [Google Scholar] [CrossRef] [Scilit]
- Zhou, X.; Lin, Z.; Shan, X.; Wang, Y.; Sun, D.; Yang, M.-H. DrivingGaussian: Composite Gaussian Splatting for Surrounding Dynamic Autonomous Driving Scenes. In Proceedings of the 2024 IEEE/CVF Conference on Computer Vision and Pattern Recognition (CVPR), Seattle, WA, USA, 16–22 June 2024; pp. 21634–21643. [Google Scholar]
- Yang, X.; Xie, W.; Peng, S.; Fu, Y.; Fan, W.; Yang, B.; Dong, X. 4D Gaussian Splatting for High-Fidelity Dynamic Reconstruction of Single-View Scenes. Neurocomputing 2025, 640, 130262. [Google Scholar] [CrossRef] [Scilit]
- Hess, G.; Lindström, C.; Fatemi, M.; Petersson, C.; Svensson, L. SplatAD: Real-Time Lidar and Camera Rendering with 3D Gaussian Splatting for Autonomous Driving. In Proceedings of the 2025 IEEE/CVF Conference on Computer Vision and Pattern Recognition (CVPR), Nashville, TN, USA, 10–17 June 2025; pp. 11982–11992. [Google Scholar]
- Go, H.; Park, B.; Jang, J.; Kim, J.-Y.; Kwon, S.; Kim, C. SplatFlow: Multi-View Rectified Flow Model for 3D Gaussian Splatting Synthesis. In Proceedings of the 2025 IEEE/CVF Conference on Computer Vision and Pattern Recognition (CVPR), Nashville, TN, USA, 10–17 June 2025; pp. 21524–21536. [Google Scholar]
- Li, Z.; Chen, Y.; Zhao, L.; Liu, P. Controllable Text-to-3D Generation via Surface-Aligned Gaussian Splatting. In Proceedings of the 2025 International Conference on 3D Vision (3DV), Singapore, 25–28 March 2025; pp. 1113–1123. [Google Scholar]
- Zhang, Z.; Kaufmann, M.; Xue, L.; Song, J.; Oswald, M.R. ODHSR: Online Dense 3D Reconstruction of Humans and Scenes from Monocular Videos. In Proceedings of the 2025 IEEE/CVF Conference on Computer Vision and Pattern Recognition (CVPR), Nashville, TN, USA, 10–17 June 2025; pp. 21824–21835. [Google Scholar]
- Zhang, J.; Li, X.; Zhong, H.; Zhang, Q.; Cao, Y.; Shan, Y.; Liao, J. HumanRef-GS: Image-to-3D Human Generation With Reference-Guided Diffusion and 3D Gaussian Splatting. IEEE Trans. Circuits Syst. Video Technol. 2025, 35, 6867–6880. [Google Scholar] [CrossRef] [Scilit]
- Shen, Q.; Yang, X.; Wang, X. FlashSplat: 2D to 3D Gaussian Splatting Segmentation Solved Optimally. In Proceedings of the Computer Vision—ECCV 2024; Leonardis, A., Ricci, E., Roth, S., Russakovsky, O., Sattler, T., Varol, G., Eds.; Springer Nature Switzerland: Cham, Switzerland, 2024; pp. 456–472. [Google Scholar]
- Zhou, K.; Hong, L.; Chang, X.; Zhong, Y.; Xie, E.; Dong, H.; Li, Z.; Yang, Y.; Li, Z.; Zhang, W. SplatMesh: Interactive 3D Segmentation and Editing Using Mesh-Based Gaussian Splatting. In Proceedings of the 2025 IEEE/CVF Conference on Computer Vision and Pattern Recognition Workshops (CVPRW), Nashville, TN, USA, 11–12 June 2025; pp. 1–12. [Google Scholar]
- Kwon, O.; Yu, J. Realistic and Interactive Virtual Museum Representation Using 3D Gaussian Splatting. ISPRS Ann. Photogramm. Remote Sens. Spat. Inf. Sci. 2025, X-M-2–2025, 185–192. [Google Scholar] [CrossRef] [Scilit]
- Zhai, H.; Zhang, X.; Zhao, B.; Li, H.; He, Y.; Cui, Z.; Bao, H.; Zhang, G. SplatLoc: 3D Gaussian Splatting-Based Visual Localization for Augmented Reality. IEEE Trans. Vis. Comput. Graph. 2025, 31, 3591–3601. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Qi, Z.; Chen, H.; Zhang, H.; Zou, Z.; Shi, Z. Efficient Semantic Splatting for Remote Sensing Multiview Segmentation. IEEE Trans. Geosci. Remote Sens. 2025, 63, 1–15. [Google Scholar] [CrossRef] [Scilit]
- Gao, K.; Lu, D.; He, H.; Xu, L.; Li, J.; Gong, Z. Enhanced 3-D Urban Scene Reconstruction and Point Cloud Densification Using Gaussian Splatting and Google Earth Imagery. IEEE Trans. Geosci. Remote Sens. 2025, 63, 1–14. [Google Scholar] [CrossRef] [Scilit]
- Huang, S.; Jiang, N.; Liang, H.; Wu, R.; Li, H. Bridge Realistic Reconstruction Algorithm Based on Improved 3D Gaussian Splatting. Laser Optoelectron. Prog. 2025, 62, 238–249. [Google Scholar] [CrossRef] [Scilit]
- Yu, Z.; Chen, A.; Huang, B.; Sattler, T.; Geiger, A. Mip-Splatting: Alias-Free 3D Gaussian Splatting. In Proceedings of the 2024 IEEE/CVF Conference on Computer Vision and Pattern Recognition (CVPR), Seattle, WA, USA, 16–22 June 2024; pp. 19447–19456. [Google Scholar]
- Yang, H.; Zhang, C.; Wang, W.; Volino, M.; Hilton, A.; Zhang, L.; Zhu, X. Improving Gaussian Splatting with Localized Points Management. In Proceedings of the 2025 IEEE/CVF Conference on Computer Vision and Pattern Recognition (CVPR), Nashville, TN, USA, 10–17 June 2025; pp. 21696–21705. [Google Scholar]
- Ye, Z.; Li, W.; Liu, S.; Qiao, P.; Dou, Y. AbsGS: Recovering Fine Details in 3D Gaussian Splatting. In Proceedings of the 32nd ACM International Conference on Multimedia; Association for Computing Machinery: New York, NY, USA, 2024; pp. 1053–1061. [Google Scholar]
- Mallick, S.S.; Goel, R.; Kerbl, B.; Steinberger, M.; Carrasco, F.V.; De La Torre, F. Taming 3DGS: High-Quality Radiance Fields with Limited Resources. In Proceedings of the SIGGRAPH Asia 2024 Conference Papers; Association for Computing Machinery: Tokyo, Japan, 2024; pp. 1–11. [Google Scholar]
- Fang, G.; Wang, B. Mini-Splatting: Representing Scenes with a Constrained Number of Gaussians. In Proceedings of the Computer Vision—ECCV 2024, Milan, Italy, 29 September–4 October 2024; pp. 165–181. [Google Scholar]
- Papantonakis, P.; Kopanas, G.; Kerbl, B.; Lanvin, A.; Drettakis, G. Reducing the Memory Footprint of 3D Gaussian Splatting. Proc. ACM Comput. Graph. Interact. Tech. 2024, 7, 1–17. [Google Scholar] [CrossRef] [Scilit]
- Tancik, M.; Casser, V.; Yan, X.; Pradhan, S.; Mildenhall, B.P.; Srinivasan, P.; Barron, J.T.; Kretzschmar, H. Block-NeRF: Scalable Large Scene Neural View Synthesis. In Proceedings of the 2022 IEEE/CVF Conference on Computer Vision and Pattern Recognition (CVPR), New Orleans, LA, USA, 18–24 June 2022; pp. 8238–8248. [Google Scholar]
- Li, R.; Fidler, S.; Kanazawa, A.; Williams, F. NeRF-XL: Scaling NeRFs with Multiple GPUs. In Proceedings of the Computer Vision—ECCV 2024, Milan, Italy, 29 September–4 October 2024; pp. 92–107. [Google Scholar]
- Chen, Y.; Lee, G.H. DOGS: Distributed-Oriented Gaussian Splatting for Large-Scale 3D Reconstruction via Gaussian Consensus. In Proceedings of the 38th International Conference on Neural Information Processing Systems, Vancouver, BC, Canada, 10–15 December 2024; Curran Associates Inc.: Red Hook, NY, USA, 2025; Volume 37, pp. 34487–34512. [Google Scholar]
- Zhao, H.; Weng, H.; Lu, D.; Li, A.; Li, J.; Panda, A.; Xie, S. On Scaling up 3D Gaussian Splatting Training. In Proceedings of the Computer Vision—ECCV 2024 Workshops; Del Bue, A., Canton, C., Pont-Tuset, J., Tommasi, T., Eds.; Springer Nature: Cham, Switzerland, 2025; pp. 14–36. [Google Scholar]
- Guan, Y.; Wang, Z.; Zhang, S.; Han, J.; Wang, W.; Wang, S.; Zhu, Y.; Lv, Y.; Zhou, W.; She, J. A Grid-Based Hierarchical Representation Method for Large-Scale Scenes Based on Three-Dimensional Gaussian Splatting. Remote Sens. 2025, 17, 1801. [Google Scholar] [CrossRef] [Scilit]
- Wu, Y.; Qi, Z.; Shi, Z.; Zou, Z. BlockGaussian: Efficient Large-Scale Scene Novel View Synthesis via Adaptive Block-Based Gaussian Splatting. arXiv 2025, arXiv:2504.09048. [Google Scholar]
- Zhang, Z.; Hu, W.; Lao, Y.; He, T.; Zhao, H. Pixel-GS: Density Control with Pixel-Aware Gradient for 3D Gaussian Splatting. In Proceedings of the Computer Vision—ECCV 2024, Milan, Italy, 29 September–4 October 2024. [Google Scholar]
- Chen, Y.; Jiang, J.; Jiang, K.; Tang, X.; Li, Z.; Liu, X.; Nie, Y. DashGaussian: Optimizing 3D Gaussian Splatting in 200 Seconds. In Proceedings of the 2025 IEEE/CVF Conference on Computer Vision and Pattern Recognition (CVPR), Nashville, TN, USA, 10–17 June 2025; pp. 11146–11155. [Google Scholar]
- Fang, G.; Wang, B. Mini-Splatting2: Building 360 Scenes within Minutes via Aggressive Gaussian Densification. arXiv 2024, arXiv:2411.12788. [Google Scholar] [CrossRef] [Scilit]
- Lin, L.; Liu, Y.; Hu, Y.; Yan, X.; Xie, K.; Huang, H. Capturing, Reconstructing, and Simulating: The UrbanScene3D Dataset. In Proceedings of the Lecture Notes in Computer Science; Avidan, S., Brostow, G., Cissé, M., Farinella, G.M., Hassner, T., Eds.; Springer Nature: Tel Aviv, Israel, 2022; pp. 93–109. [Google Scholar]
- Li, Y.; Jiang, L.; Xu, L.; Xiangli, Y.; Wang, Z.; Lin, D.; Dai, B. MatrixCity: A Large-Scale City Dataset for City-Scale Neural Rendering and Beyond. In Proceedings of the 2023 IEEE/CVF International Conference on Computer Vision (ICCV), Paris, France, 1–6 October 2023; pp. 3182–3192. [Google Scholar]
- Pix4D. Example Projects—Real Photogrammetry Data; Pix4D: Prilly, Switzerland, 2025. [Google Scholar]
- Mi, Z.; Xu, D. Switch-NeRF: Learning Scene Decomposition with Mixture of Experts for Large-Scale Neural Radiance Fields; International Conference on Learning Representations, ICLR: Kigali, Rwanda, 2023; pp. 6322–6336. [Google Scholar]
- PlayCanvas. SuperSplat 3DGS Viewer Is Now Open Source; PlayCanvas: London, UK, 2024. [Google Scholar]

| Method | Partitioning | Supervision/Boundary Handling | Density/Scale Control |
|---|---|---|---|
| VastGaussian | Camera-position-based grid partitioning on the ground plane; each cell contains a similar number of training views. | Airspace-aware visibility-based camera selection and coverage-based SfM point selection to enrich supervision and reduce floaters. | Original 3DGS densification/pruning within each cell; no frequency-guided multi-scale training is reported. |
| CityGaussian | Uniform grid partitioning applied to a contracted global Gaussian prior in a bounded cubic space. | Coarse global Gaussian model used as initialization; SSIM-based view assignment combined with camera location to select training views for each block. | Decomposed-gradient-based densification; block-wise level-of-detail representation mainly for efficient rendering. |
| BlockGaussian | Recursive bisection of the ground-plane sparse SfM point cloud, yielding content-aware blocks of varying size. | Auxiliary point clouds together with visibility-aware block optimization and a pseudo-view geometry constraint to mitigate supervision mismatch and boundary artifacts. | Original 3DGS densification; no explicit multi-scale training schedule is introduced. |
| The proposed work | KD-tree subdivision on the ground plane guided by SfM point density, with joint control of point count and view–region correlation to balance computational load across blocks. | Overlapping regions and non-densifying auxiliary Gaussians to preserve cross-block geometric and photometric consistency while controlling model growth. | Pixel-weighted adaptive density control and a frequency-aware multi-scale training strategy over image resolution and Gaussian budget. |
| Method | Number of Gaussians | Training Time (s) |
|---|---|---|
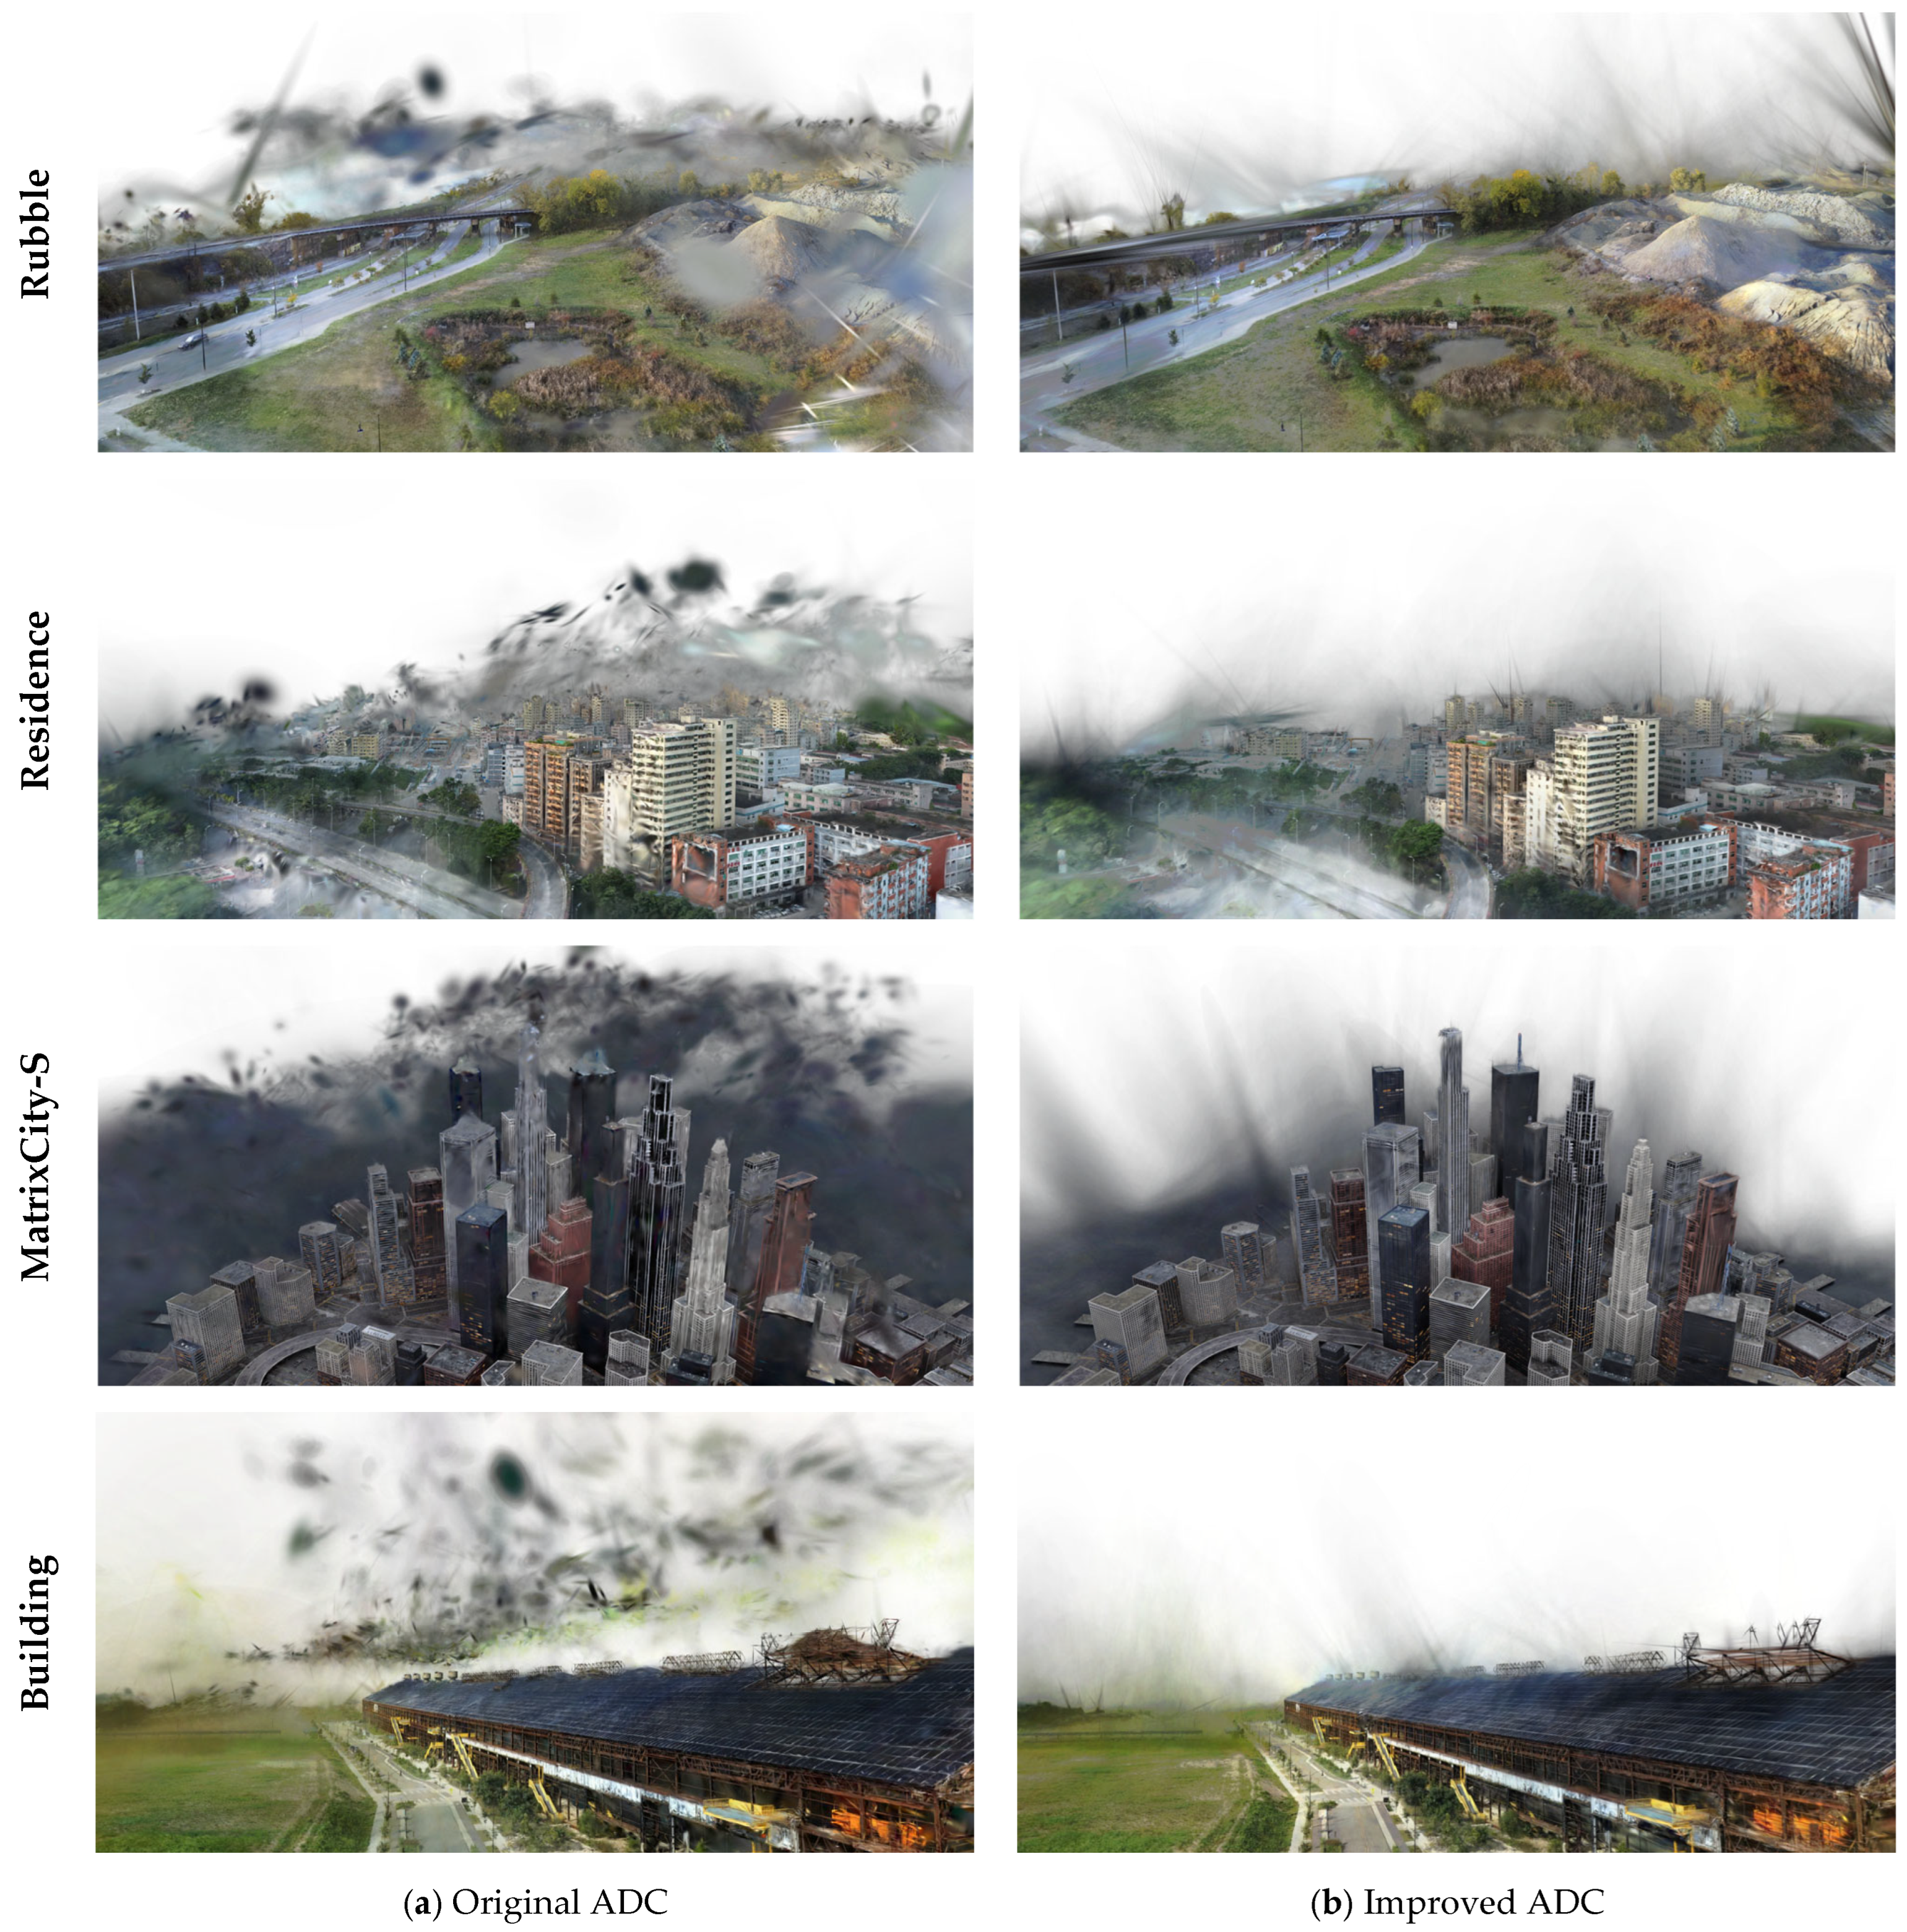
| Original ADC | 9,190,727 | 4362.28 |
| ADC Based on Pixel-Weight Scaling | 15,834,676 | 6320.63 |
| Datasets | Training Images | Testing Images | Resolution (px) | Average Size (MB) | Cover Area |
|---|---|---|---|---|---|
| Rubble | 1657 | 21 | 4608 × 3456 | 6 | 206 × 248 |
| Building | 1920 | 20 | 4608 × 3456 | 6 | 262 × 438 |
| Residence | 2561 | 21 | 5472 × 3648 | 2.5 | 291 × 491 |
| Sci-Art | 2998 | 21 | 4864 × 3648 | 2 | 373 × 317 |
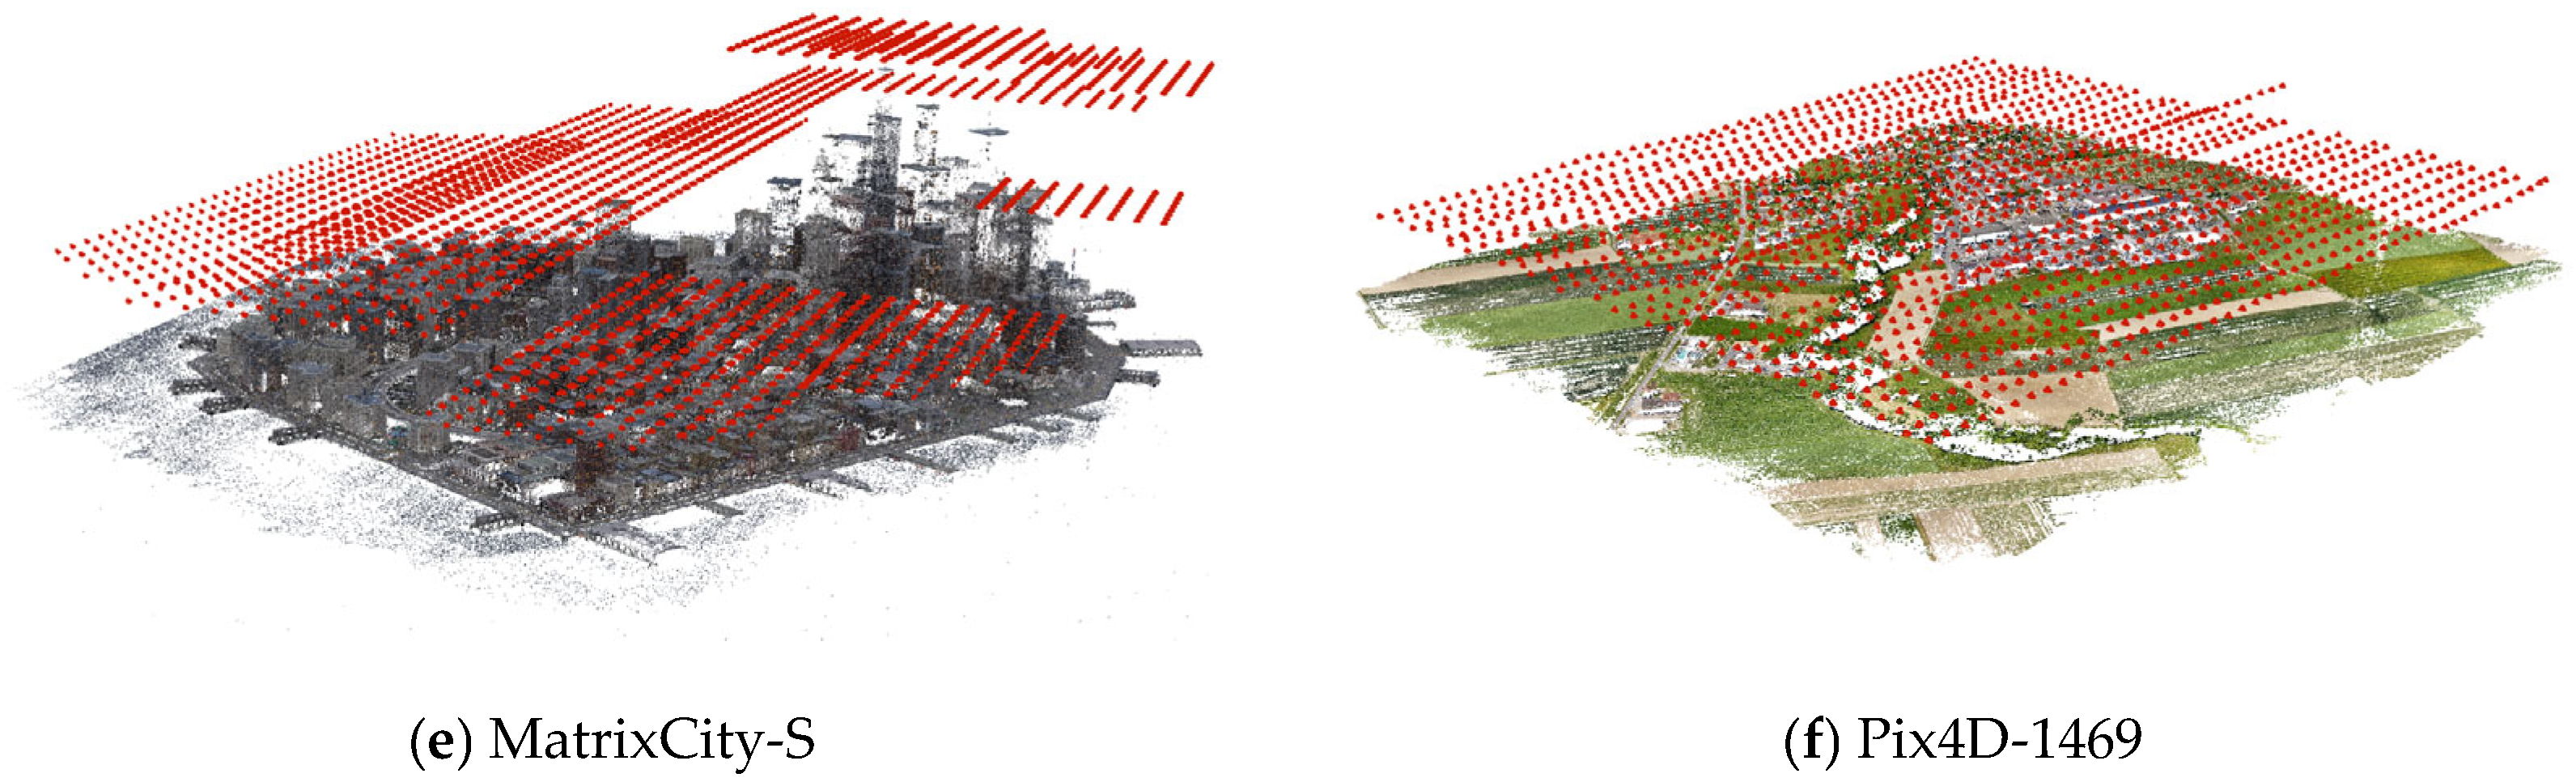
| MatrixCity-S | 6362 | 741 | 1920 × 1080 | 4 | 2.7 |
| Pix4D-1469 | 1454 | 15 | 5958 × 3972 | 16 | 1.2 |
| GPU | FP32 Compute Performance (TFLOPS) | Tensor Performance 1 (FP16) | AI TOPS 2 (INT8) | Performance Comparison (baseline: RTX 3090) |
|---|---|---|---|---|
| RTX 3090 | 35.6 | 71 | 142 | 1× |
| RTX 5070 | 48.7 | 97.5 | 389.9 | 1.4× |
| RTX 4090 | 82.6 | 82.6 | 661 | 2.3× |
| RTX 5090 | 104.8 | 838 | 3352 | 2.9× |
| Method | GPU | Densification Configuration | Iteration Budget & Schedule | Down-Sampling |
|---|---|---|---|---|
| 3DGS | Single RTX 3090 | Original gradient-based ADC; default densification configuration | Default schedule | Default config |
| CityGS | Multi-GPU | Native CityGaussian training settings | Default schedule | Default config |
| DOGS | Multi-GPU | Original DOGS densification & distributed scheme | Default schedule | Default config |
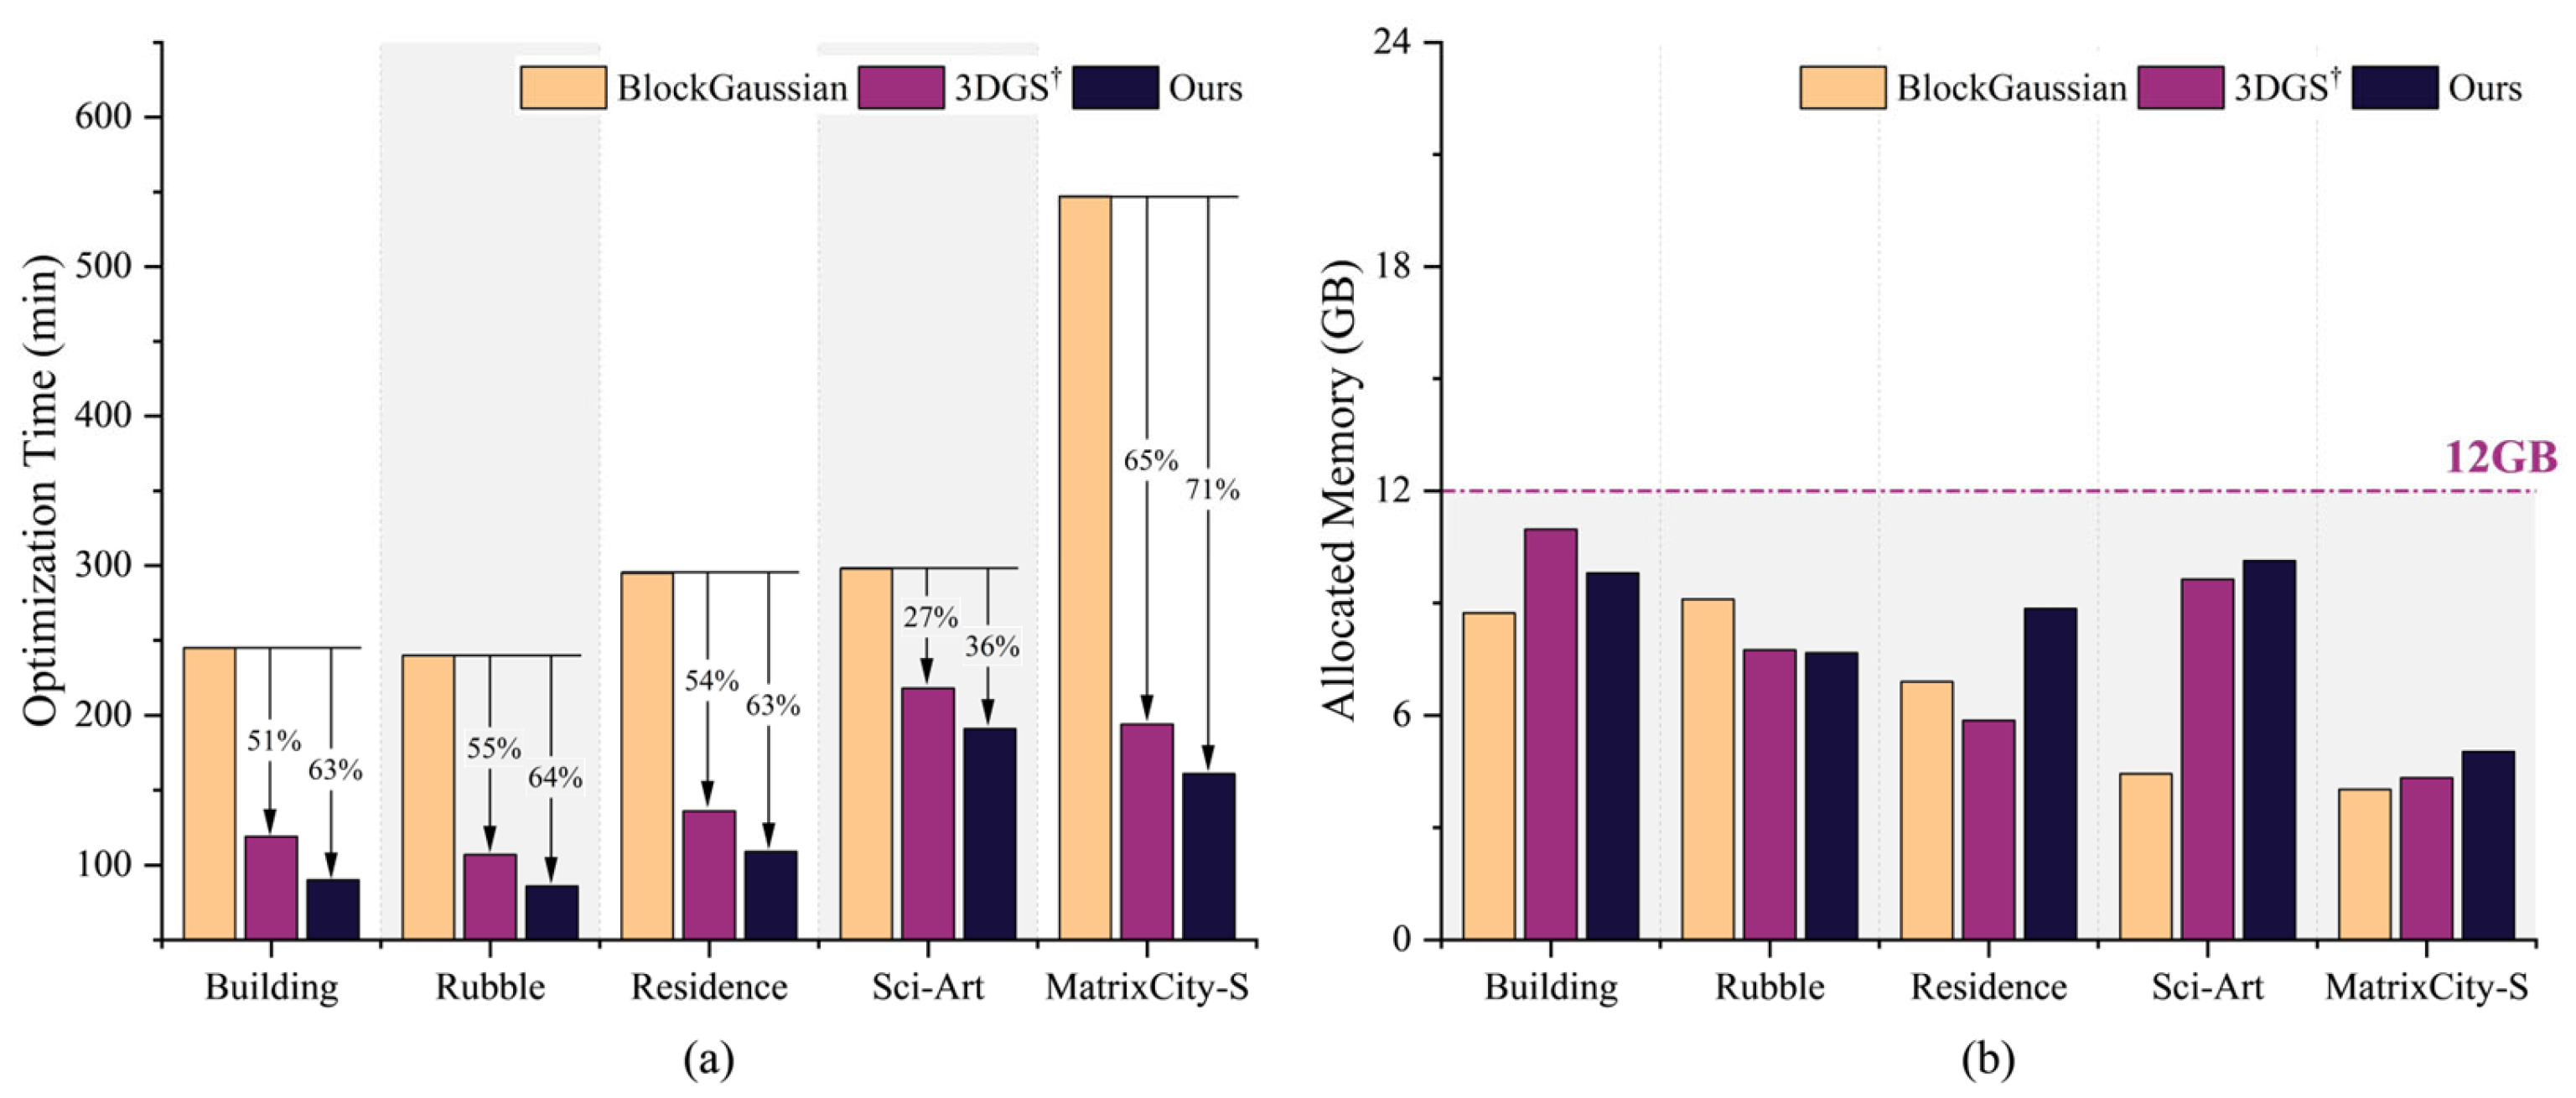
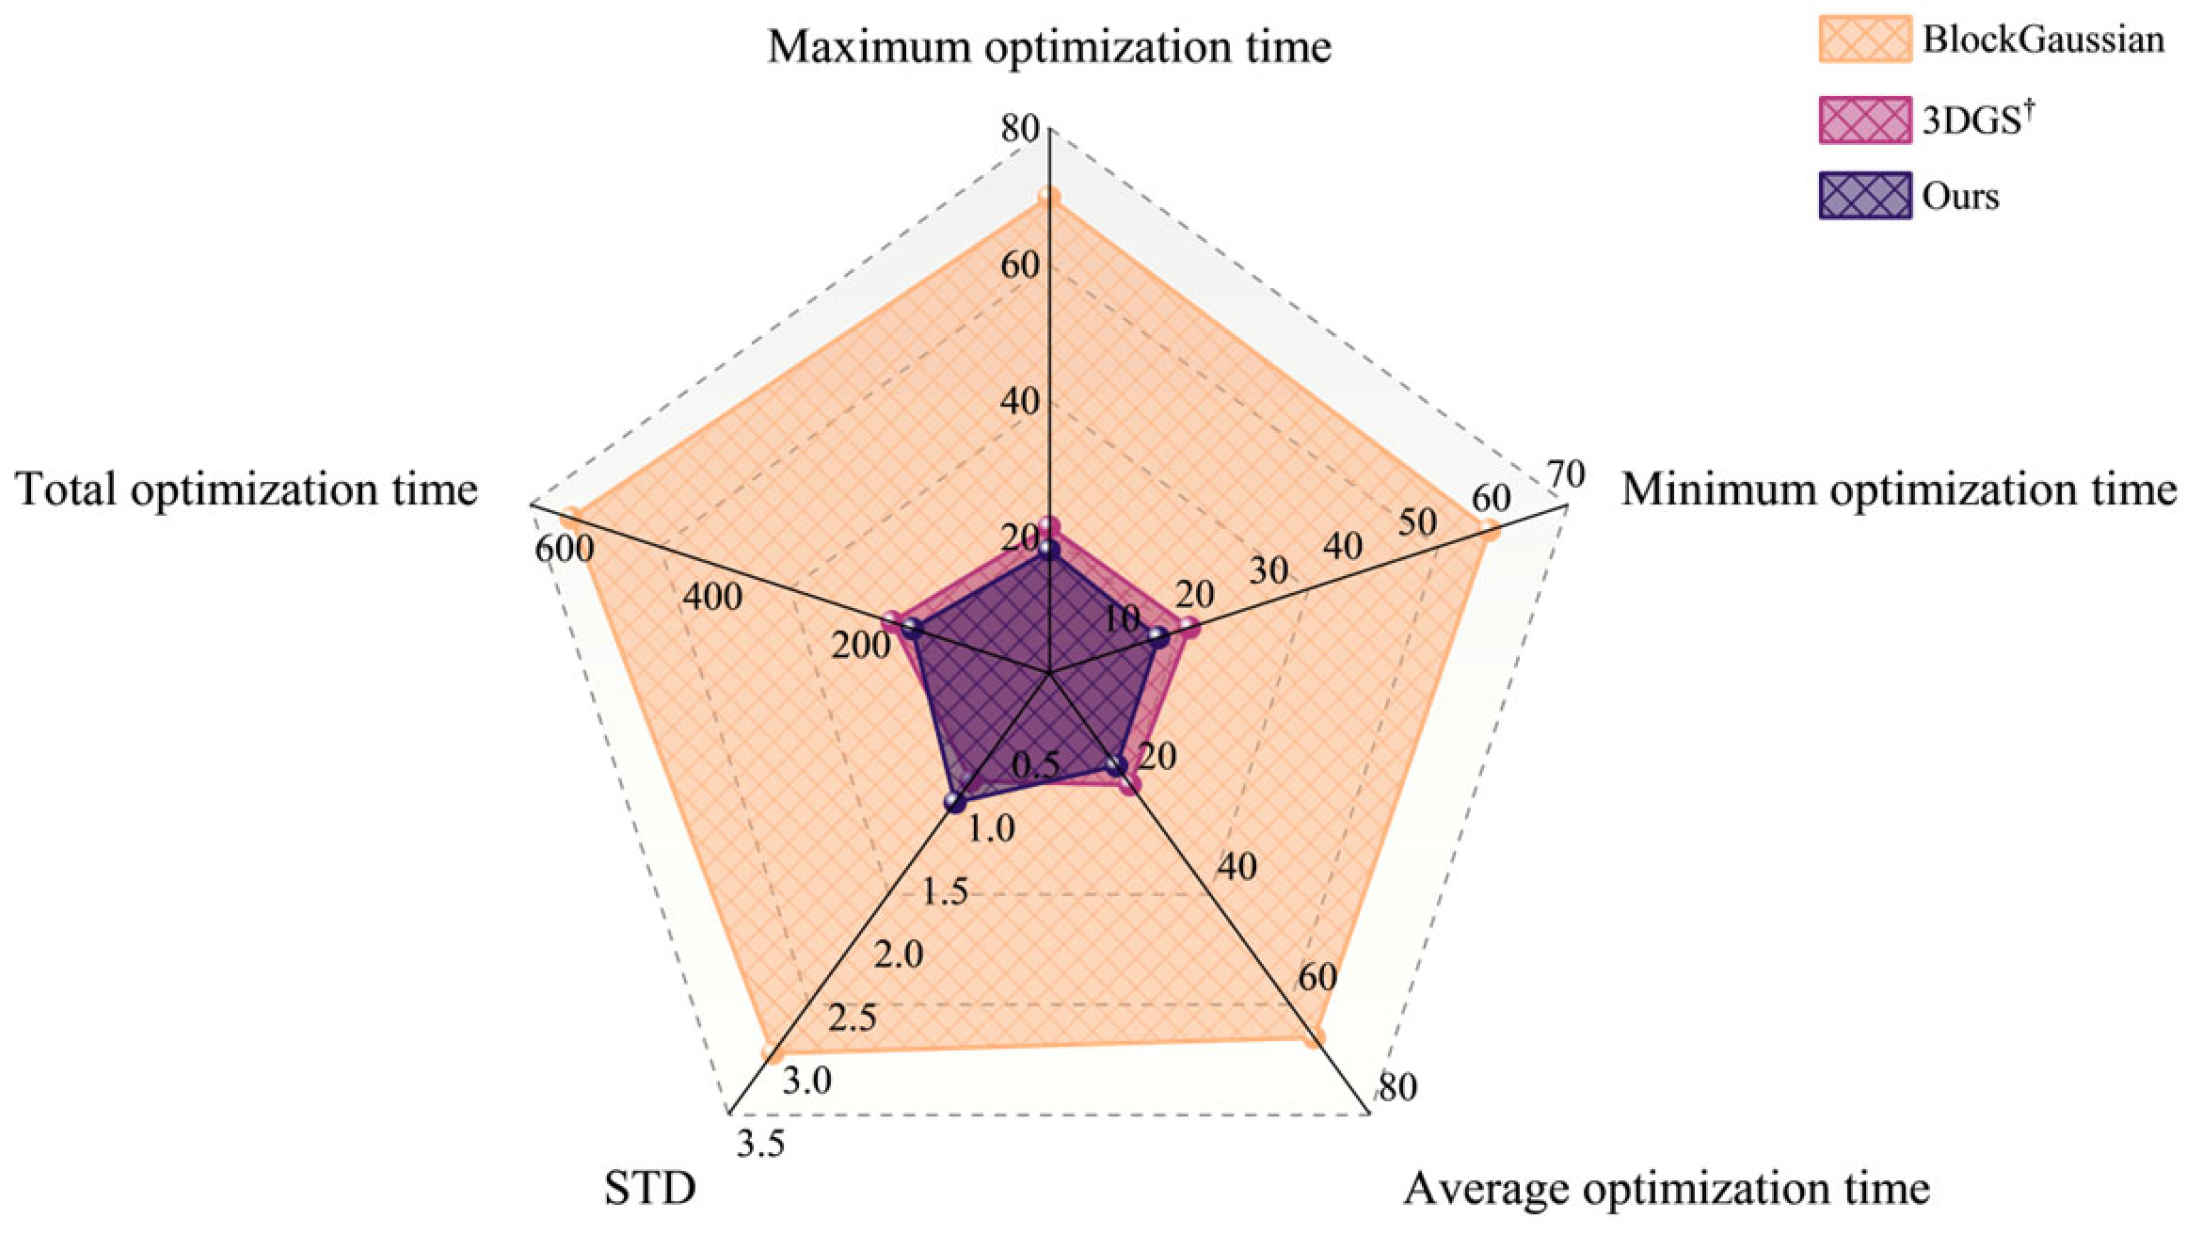
| 3DGS† | Single RTX 3090 | Original gradient-based ADC; densification iterations [1000, 17,500]; cycles: 150/400/500 | 35,000 | 0.25 |
| BlockGaussian | Single RTX 3090 | Densification iterations [1000, 20,000]; cycle = 200 (750 for Pix4D-1469 to avoid OOM) | 40,000 | 0.25 |
| Ours | Single RTX 3090 | Pixel-weighted ADC with scaling; adaptive multi-scale scheduling; densification [1000, 17,500]; cycles: 150/400/500 | 35,000 | 0.25 |
| Scenes | Building | Rubble | ||||||
|---|---|---|---|---|---|---|---|---|
| PSNR↑ | SSIM↑ | LPIPS↓ | Train↓ | PSNR↑ | SSIM↑ | LPIPS↓ | Train↓ | |
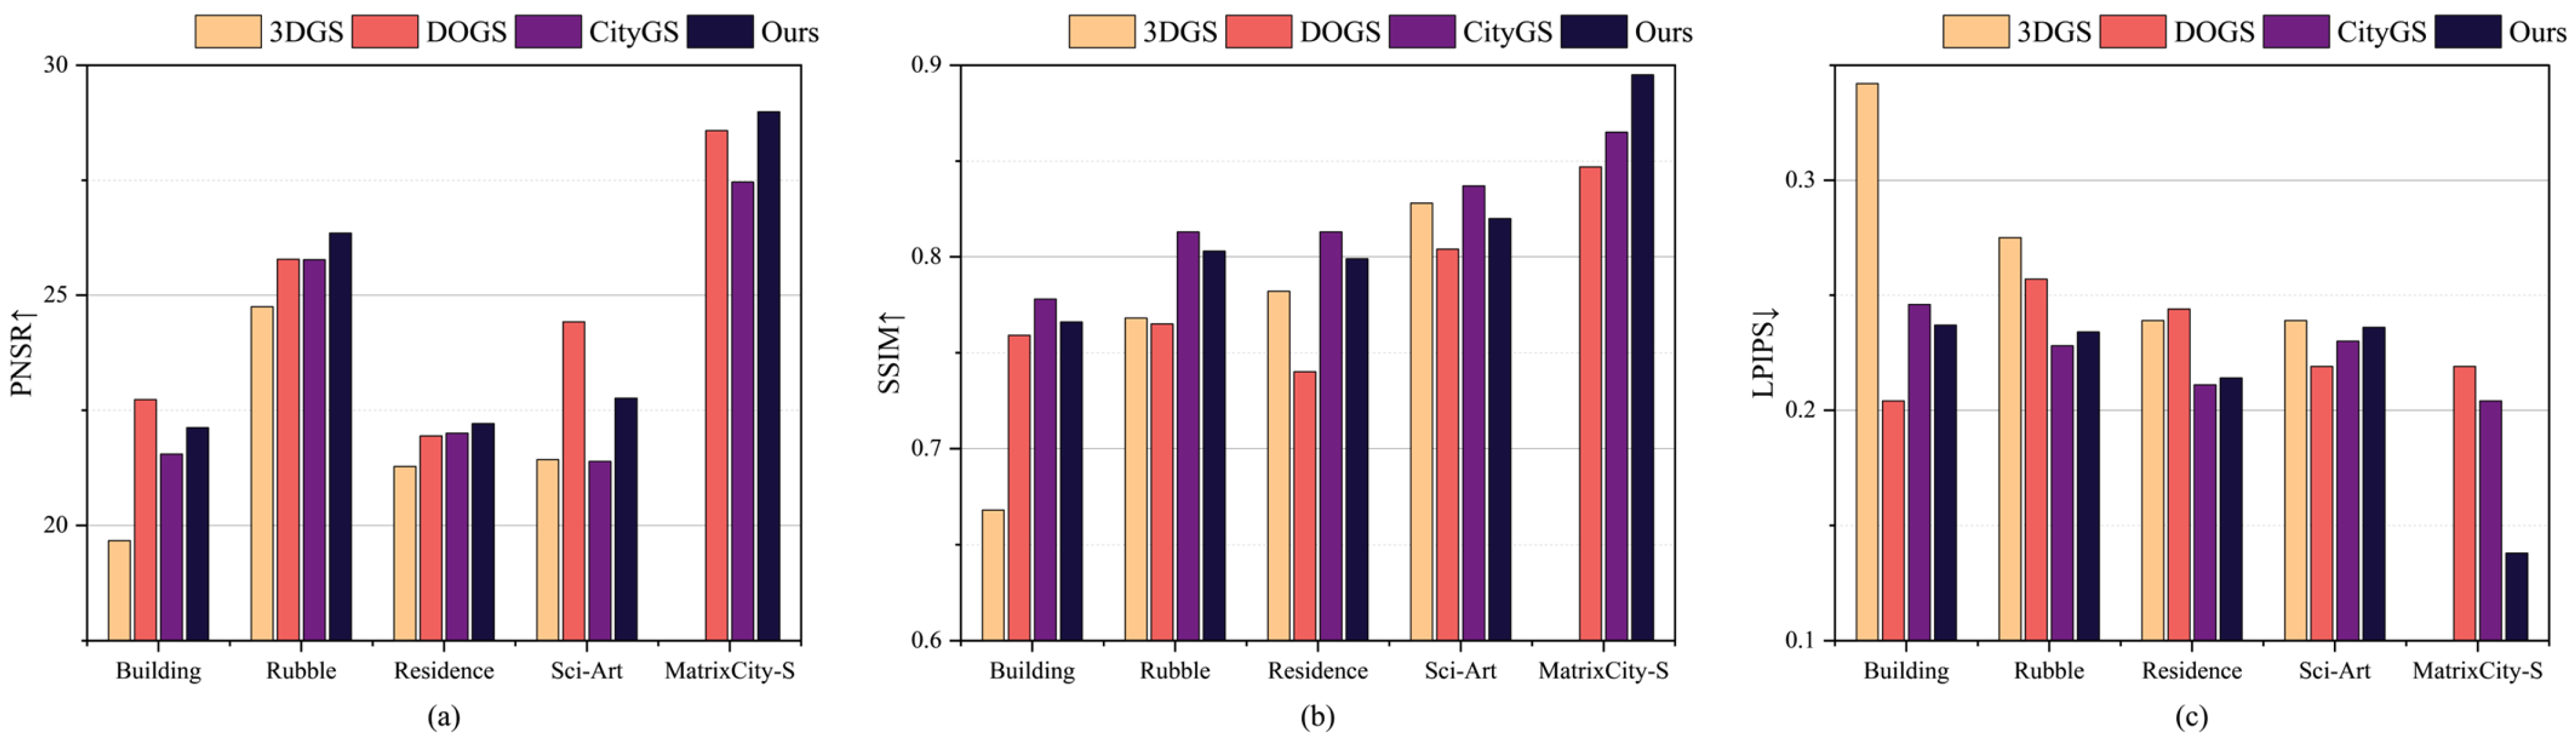
| Mega-NeRF | 20.92 | 0.547 | 0.454 | 19 h 49 min | 24.06 | 0.553 | 0.508 | 30 h 48 min |
| Switch-NeRF [51] | 21.54 | 0.579 | 0.397 | 24 h 46 min | 24.31 | 0.562 | 0.478 | 38 h 30 min |
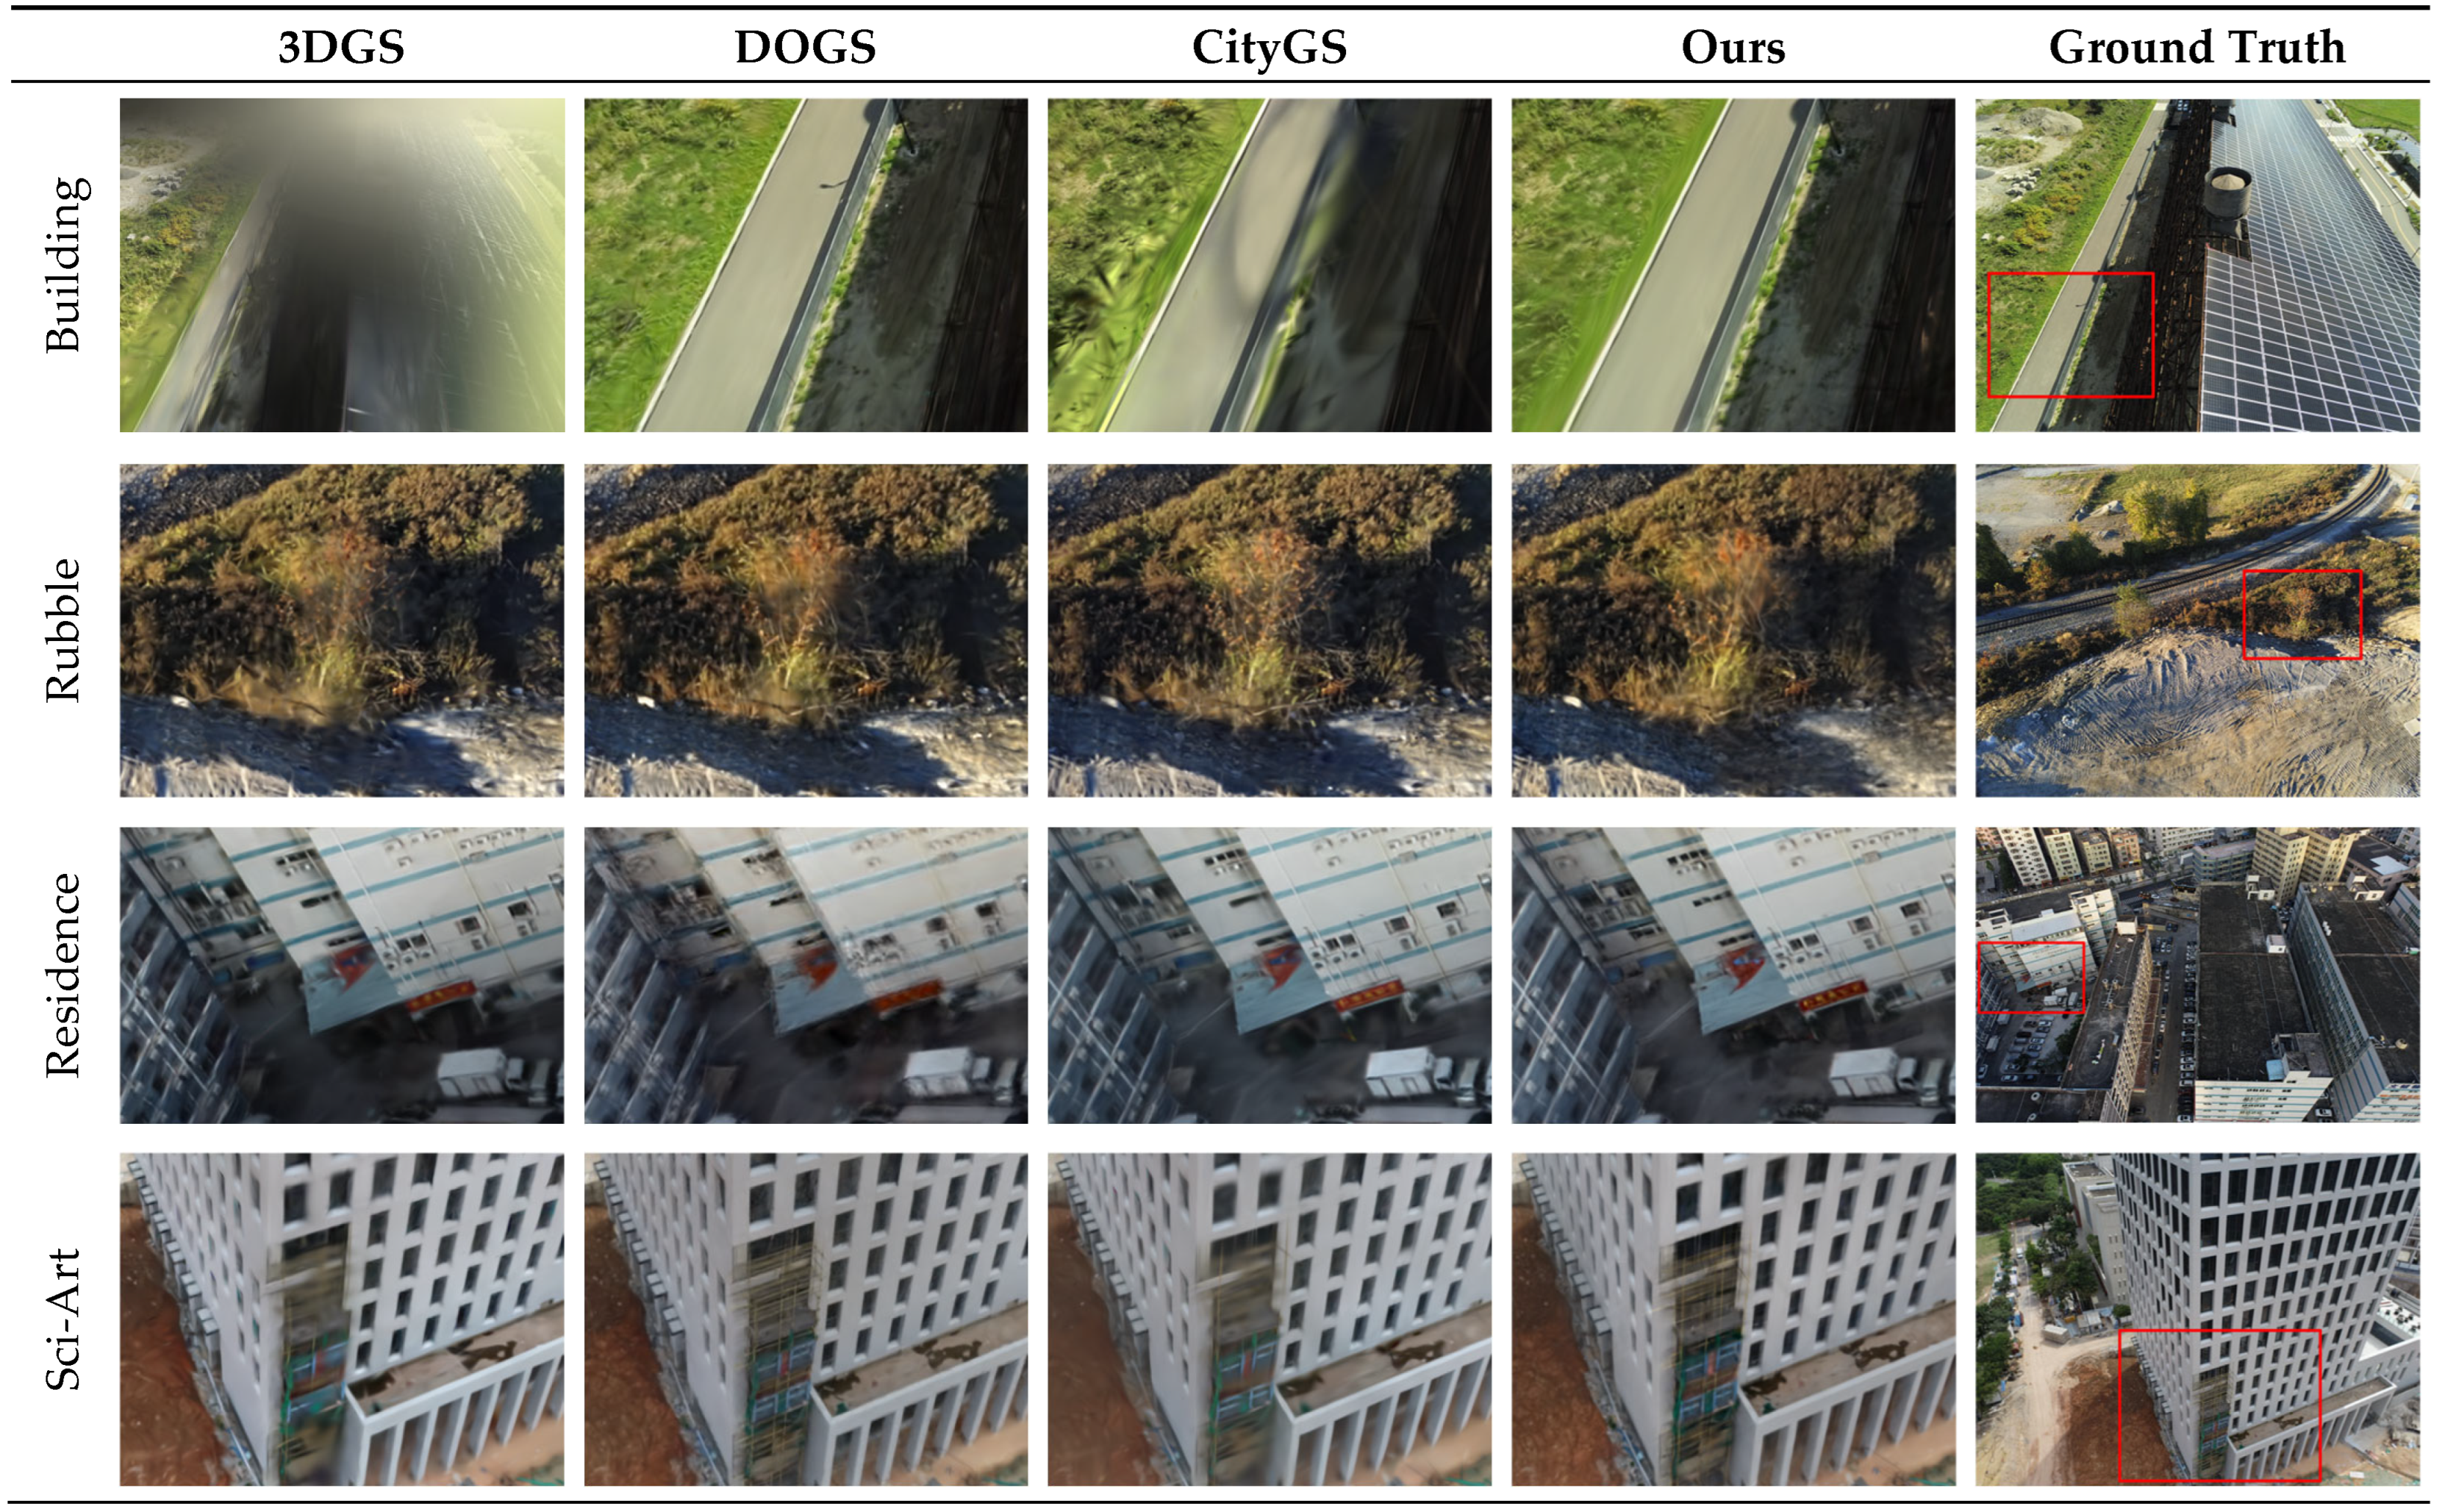
| 3DGS | 19.67 | 0.668 | 0.342 | 01 h 29 min | 24.75 | 0.768 | 0.275 | 01 h 35 min |
| DOGS | 22.73 | 0.759 | 0.204 | 03 h 51 min | 25.78 | 0.765 | 0.257 | 02 h 25 min |
| CityGS | 21.55 | 0.778 | 0.246 | - | 25.77 | 0.813 | 0.228 | - |
| Ours | 22.12 | 0.766 | 0.237 | 01 h 31 min | 26.35 | 0.803 | 0.234 | 01 h 26 min |
| Scenes | Residence | Sci-Art | ||||||
|---|---|---|---|---|---|---|---|---|
| PSNR↑ | SSIM↑ | LPIPS↓ | Train↓ | PSNR↑ | SSIM↑ | LPIPS↓ | Train↓ | |
| Mega-NeRF | 22.08 | 0.628 | 0.401 | 27 h 20 min | 25.60 | 0.770 | 0.312 | 27 h 39 min |
| Switch-NeRF | 22.57 | 0.654 | 0.352 | 35 h 11 min | 26.51 | 0.795 | 0.271 | 34 h 34 min |
| 3DGS | 21.28 | 0.782 | 0.239 | 01 h 42 min | 21.43 | 0.828 | 0.239 | 00 h 53 min |
| DOGS | 21.94 | 0.740 | 0.244 | 04 h 33 min | 24.42 | 0.804 | 0.219 | 04 h 23 min |
| CityGS | 22.00 | 0.813 | 0.211 | - | 21.39 | 0.837 | 0.230 | - |
| Ours | 22.21 | 0.799 | 0.214 | 01 h 49 min | 22.76 | 0.820 | 0.236 | 03 h 11 min |
| Scenes | MatrixCity-S | |||
|---|---|---|---|---|
| PSNR↑ | SSIM↑ | LPIPS↓ | Train↓ | |
| 3DGS | OOM | |||
| DOGS | 28.58 | 0.847 | 0.219 | 06 h 34min |
| CityGS | 27.46 | 0.865 | 0.204 | - |
| Ours | 28.99 | 0.895 | 0.138 | 02 h 41 min |
| Method | Building | Rubble | Residence | Sci-Art | ||||||||||||
|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|
| PSNR | SSIM | LPIPS | #GS * | PSNR | SSIM | LPIPS | #GS | PSNR | SSIM | LPIPS | #GS | PSNR | SSIM | LPIPS | #GS | |
| BlockGaussian | 22.08 | 0.762 | 0.237 | 13.45 | 25.77 | 0.790 | 0.239 | 10.20 | 22.46 | 0.803 | 0.211 | 9.63 | 22.44 | 0.814 | 0.231 | 4.63 |
| 3DGS† | 22.17 | 0.763 | 0.240 | 17.51 | 26.42 | 0.809 | 0.225 | 14.47 | 22.01 | 0.798 | 0.214 | 15.56 | 22.68 | 0.822 | 0.218 | 9.64 |
| Ours | 22.12 | 0.766 | 0.237 | 18.55 | 26.35 | 0.803 | 0.234 | 11.79 | 22.21 | 0.799 | 0.214 | 14.62 | 22.76 | 0.820 | 0.236 | 8.19 |
| Method | MatrixCity-S | |||
|---|---|---|---|---|
| PSNR | SSIM | LPIPS | #GS | |
| BlockGaussian | 29.13 | 0.900 | 0.131 | 19.15 |
| 3DGS† | 28.54 | 0.892 | 0.140 | 25.14 |
| Ours | 28.99 | 0.895 | 0.138 | 28.80 |
| Dataset | Method | PSNR | SSIM | LPIPS | #GS * | Opt. Time (min) | Mem (GB) |
|---|---|---|---|---|---|---|---|
| Pix4D-1469 | BlockGaussian | OOM | 39.99 | 595 | 10.606 | ||
| 3DGS† | 23.72 | 0.671 | 0.368 | 21.10 | 167 | 8.323 | |
| Ours | 23.71 | 0.698 | 0.344 | 27.34 | 144 | 6.693 | |
| Scenes | ||||||||||
|---|---|---|---|---|---|---|---|---|---|---|
| Building | 4 | 637 | 39.18 | 6.15% | 348,470 | 6770.10 | 1.94% | 5141 | 128.71 | 10.01% |
| Rubble | 4 | 544 | 49.98 | 9.19% | 396,540 | 10,109.78 | 2.55% | 4912 | 52.67 | 4.29% |
| Residence | 4 | 857 | 27.23 | 3.18% | 408,245 | 8798.81 | 2.16% | 6025 | 78.89 | 5.24% |
| Sci-Art | 8 | 893 | 270.75 | 30.32% | 339,382 | 108,859.38 | 32.08% | 10,384 | 210.61 | 16.23% |
| MatrixCity-S | 16 | 469 | 69.47 | 14.81% | 192,594 | 2427.13 | 1.26% | 9333 | 63.64 | 10.91% |
| Scene-Content Complexity-Based Partitioning | Subregion Training Based on Auxiliary Point Clouds | PSNR | SSIM | LPIPS | Train (s) | Mem (GB) |
|---|---|---|---|---|---|---|
| ☓ | ☓ | 19.67 | 0.668 | 0.342 | 5312 | 13.33 |
| √ | ☓ | 21.34 | 0.729 | 0.261 | 5514 | 6.64 |
| √ | √ | 22.12 | 0.766 | 0.237 | 5434 | 8.65 |
| Weight Scaling | Adaptive Multiscale | PSNR | SSIM | LPIPS | Train (s) | Opt. Time Proportion |
|---|---|---|---|---|---|---|
| ☓ | ☓ | 25.94 | 0.792 | 0.289 | 4362 | 1.00× |
| √ | ☓ | 26.37 | 0.812 | 0.233 | 6320 | 1.45× |
| ☓ | √ | 25.78 | 0.785 | 0.256 | 3529 | 0.81× |
| √ | √ | 26.35 | 0.803 | 0.234 | 5165 | 1.18× |
Disclaimer/Publisher’s Note: The statements, opinions and data contained in all publications are solely those of the individual author(s) and contributor(s) and not of MDPI and/or the editor(s). MDPI and/or the editor(s) disclaim responsibility for any injury to people or property resulting from any ideas, methods, instructions or products referred to in the content. |
© 2025 by the authors. Licensee MDPI, Basel, Switzerland. This article is an open access article distributed under the terms and conditions of the Creative Commons Attribution (CC BY) license (https://creativecommons.org/licenses/by/4.0/).
Share and Cite
Yan, K.; Wang, H.; Li, Z.; Wang, Y.; Li, S.; Yang, H. A Large-Scale 3D Gaussian Reconstruction Method for Optimized Adaptive Density Control in Training Resource Scheduling. Remote Sens. 2025, 17, 3868. https://doi.org/10.3390/rs17233868
Yan K, Wang H, Li Z, Wang Y, Li S, Yang H. A Large-Scale 3D Gaussian Reconstruction Method for Optimized Adaptive Density Control in Training Resource Scheduling. Remote Sensing. 2025; 17(23):3868. https://doi.org/10.3390/rs17233868
Chicago/Turabian StyleYan, Ke, Hui Wang, Zhuxin Li, Yuting Wang, Shuo Li, and Hongmei Yang. 2025. "A Large-Scale 3D Gaussian Reconstruction Method for Optimized Adaptive Density Control in Training Resource Scheduling" Remote Sensing 17, no. 23: 3868. https://doi.org/10.3390/rs17233868
APA StyleYan, K., Wang, H., Li, Z., Wang, Y., Li, S., & Yang, H. (2025). A Large-Scale 3D Gaussian Reconstruction Method for Optimized Adaptive Density Control in Training Resource Scheduling. Remote Sensing, 17(23), 3868. https://doi.org/10.3390/rs17233868

