Skip to Content
  • 3.6
    Impact Factor
  • 7.4
    CiteScore
  • 21 days
    Submission to First Decision
  • 4 days
    Acceptance to Publication

Robotics

Robotics is an international, peer-reviewed, open access journal on robotic systems in theory, design, and applications, published monthly online by MDPI. The International Federation for the Promotion of Mechanism and Machine Science (IFToMM) and Robotic Global Surgical Society (TROGSS) are affiliated with Robotics and its members receive a discount on the article processing charges.

Get Alerted

Add your email address to receive forthcoming issues of this journal.

All Articles (1,469)

  • Article
  • Open Access

Evaluation of a Rapid-Response Mechanism in Embedded Child Restraint Seat for Cars

  • Luis Angel Guerrero-Hernández,
  • Marco Ceccarelli and
  • Christopher Rene Torres-SanMiguel
  • + 1 author

This paper presents a numerical and energy-based assessment of a rapid-response linkage mechanism intended for an embedded child restraint seat. It is modeled as a rapid-repositioning device that modifies the child–seat system’s kinematic configuration. A single-degree-of-freedom model under base excitation represents the child–seat interaction during a frontal impact. We compare the reference case without the mechanism with a mechanism-enabled case using equivalent impact pulses with the same velocity change. The rapid-response input is limited to a 15 mm displacement in 0.1 s, corresponding to the maximum mechanical travel of the guided-slider region. The comparison is based on relative displacement, transmitted force, and positive accumulated transmitted energy. We evaluate mechanical performance indices to quantify the mechanism’s effect. A sensitivity study examines pulse shape, equivalent stiffness, damping ratio, child mass, activation delay, and partial mechanism displacement. Under the nominal half-sine pulse, the mechanism-enabled case reduces the maximum relative displacement by 0.99%, the maximum transmitted force by 0.99%, and the positive accumulated transmitted energy by 1.59%. The results are preliminary mechanical indicators, not injury criteria or regulatory validation. The proposed framework provides a design tool for evaluating rapid-response mechanisms before experimental and biomechanical testing.

Robotics

24 October 2026
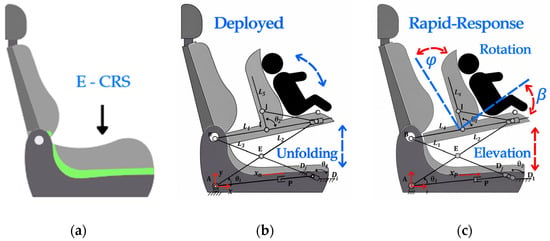
Design concept of the embedded child restraint seat: (a) stored configuration inside the rear seat; (b) deployed child-seat configuration; and (c) rapid-response configuration with lifting and backrest angular repositioning.
  • Article
  • Open Access

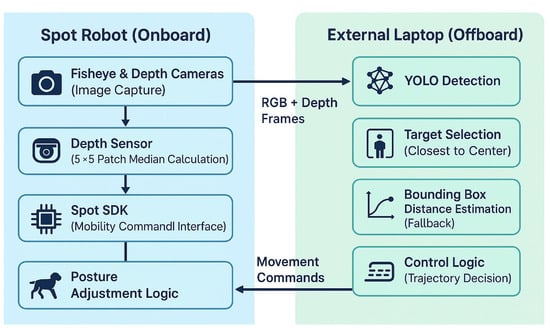
Human following by quadruped robots is a coupled perception–control problem in which detection availability, identity continuity, ranging reliability, and latency jointly determine behavior. This study experimentally evaluates a camera-based human-following pipeline on Boston Dynamics Spot. The final RGB-only follow loop combines YOLOv8n person-detection, DeepSORT tracking, monocular geometric ranging from bounding-box width, and bounded linear/yaw velocity control; spot depth was evaluated only as an alternative range source. YOLOv8n achieved 59.0% frame-level detection success indoors (36/61; 95% CI 46.5–70.5%) at 113.7 ms mean inference latency, and 38.75% outdoors (31/80; 95% CI 28.8–49.7%) at 118.1 ms. DeepSORT produced zero observed ID switches and fragmentations in 51 indoor and 45 outdoor multi-person frames, at about 3.2 FPS. On 12 outdoor frames with field-reference distances, geometric ranging yielded MAE 0.264 m and RMSE 0.323 m; spot depth was valid in only three frames. Continuous velocity control provided qualitatively smoother following than discrete commands and stopped on target loss. The study contributes a reproducible system-level analysis of practical design trade-offs and failure modes in camera-based human following by a commercial quadruped robot.

Robotics

23 October 2026

Development-stage modular architecture of the Boston Dynamics Spot human-following system. The diagram shows image acquisition, depth sampling, simple target selection, bounding-box ranging, and Spot control. In the final implementation, the target-selection block was replaced by DeepSORT identity tracking, as described in Section 3.5, and geometric ranging was used for the closed-loop distance signal.
  • Systematic Review
  • Open Access

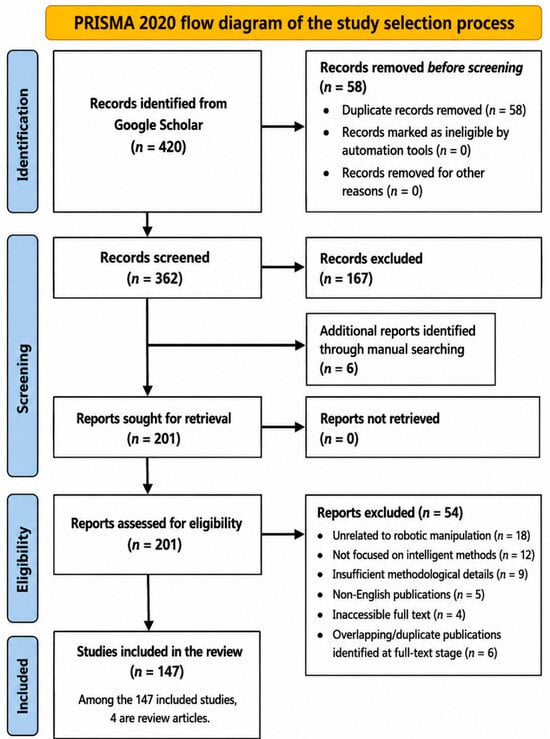
Kinematic modeling and path planning are critical problems in intelligent automation that directly affect the precision, adaptability, and safety of robotic arms. The ever-growing complexity of manipulators, including redundant DOFs, unique kinematic architectures, and environmental dynamics, has highlighted the drawbacks of classic analytical and Jacobian approaches in handling singularities, computational costs, and generalizability. Despite many reviews addressing particular problems such as inverse kinematics or reinforcement learning, an extensive overview of methodological development is yet to be provided. The sources for the literature review were mainly obtained from Google Scholar, while the publishing details for the selected articles were then cross-checked using the individual publishers’ and journal sites. The sources are divided into the following nine categories: analytical and hybrid inverse kinematics, neural networks, optimization, deep reinforcement learning, sampling- and learning-based motion planning, diffusion models, trajectory optimization, obstacle avoidance, and imitation learning. From the review, it is evident that there is a shift from traditional approaches such as analysis and optimization to AI-based methods like neural networks, deep reinforcement learning, and diffusion-based systems, with 105 studies published between 2022 and 2026. Some of the findings include MLP-based inverse kinematics (R2 > 0.99), meta-heuristic optimization resulting in a 4.75 × 10⁻⁴ cm position error, a 99.4% path-planning success rate through reinforcement learning, diffusion-based visuomotor control, and challenges facing intelligent robotic manipulation research.

Robotics

22 October 2026

PRISMA 2020 flow diagram illustrating the systematic literature selection process and final inclusion of 147 studies.
  • Feature Paper
  • Article
  • Open Access

Diffusion-Guided Trajectory Priors for Efficient Robotic Manipulator Motion Planning in Dynamic Environments

  • Rajesh Kannan Megalingam,
  • Sakthiprasad Kuttankulangara Manoharan and
  • Sindhu Sankar

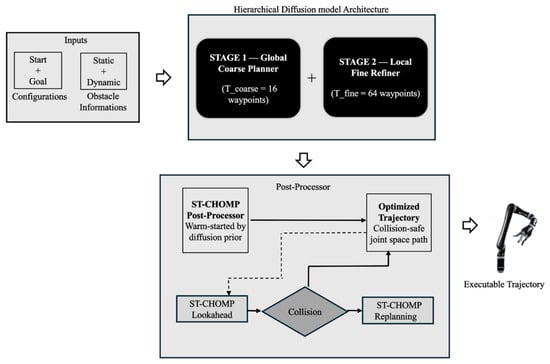
Real-time trajectory planning for 6-DoF robotic manipulators in environments containing moving obstacles remains an open challenge because planners must simultaneously satisfy collision avoidance, joint limits, and strict latency constraints. Existing diffusion-based planners suffer from three structural limitations: single-resolution denoising that forces global topology and local geometry to compete for model capacity within a single pass; static obstacle snapshots applied uniformly across all trajectory waypoints, which is incorrect because the obstacle moves by the time the arm reaches waypoints several seconds into the future; and scalar collision guidance that cannot localize corrective effort along the trajectory. In this paper, a hierarchical conditional diffusion framework is proposed for structured joint-space trajectory generation, which is conditioned on start and goal positions, static workspace geometry, and dynamic obstacle motions. To guarantee temporal consistency, a spatio-temporal cross-attention module is employed to align each waypoint query with predicted obstacle state at its corresponding execution time. Furthermore, a learned GuidanceScheduler is proposed that uses a waypoint-wise collision penalty profile, enabling temporally directed guidance during denoising instead of a scalar penalty. The framework is trained on 10,800 expert trajectories for the Kinova J2S6S300 manipulator and evaluated on 1200 held-out scenarios. It achieves 93.5% planning success versus 82.5% for the best learning-based baseline, Hierarchical Diffusion Policy (HDP), an absolute improvement of 11 percentage points, and 95.0% when combined with ST-CHOMP post-processing, at 243 ms inference latency.

Robotics

22 October 2026

Proposed system architecture.

Featured Articles of Last Quarter

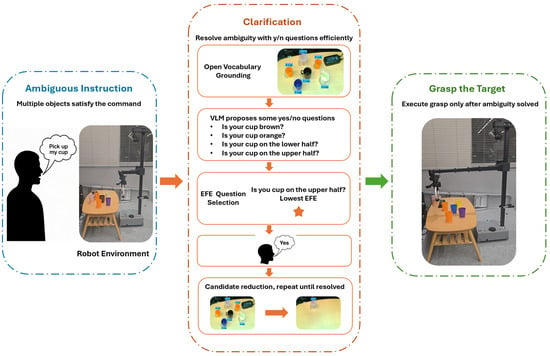
Conceptual overview of ActivAsk. An ambiguous instruction can match several objects in the robot workspace. ActivAsk constructs plausible candidates, asks candidate-grounded yes/no clarification questions, selects an informative question using an expected free energy (EFE) rule, updates the candidate state from the user answer, and executes the grasp only after the intended target is resolved.

Highly Accessed Articles

News & Conferences

Latest Issues

Open for Submission

Journal Sections

XFacebookLinkedIn
Robotics - ISSN 2218-6581