Design and Evaluation of an Underactuated Rigid–Flexible Coupled End-Effector for Non-Destructive Apple Harvesting

 ,
Abstract
1. Introduction
2. Materials and Methods
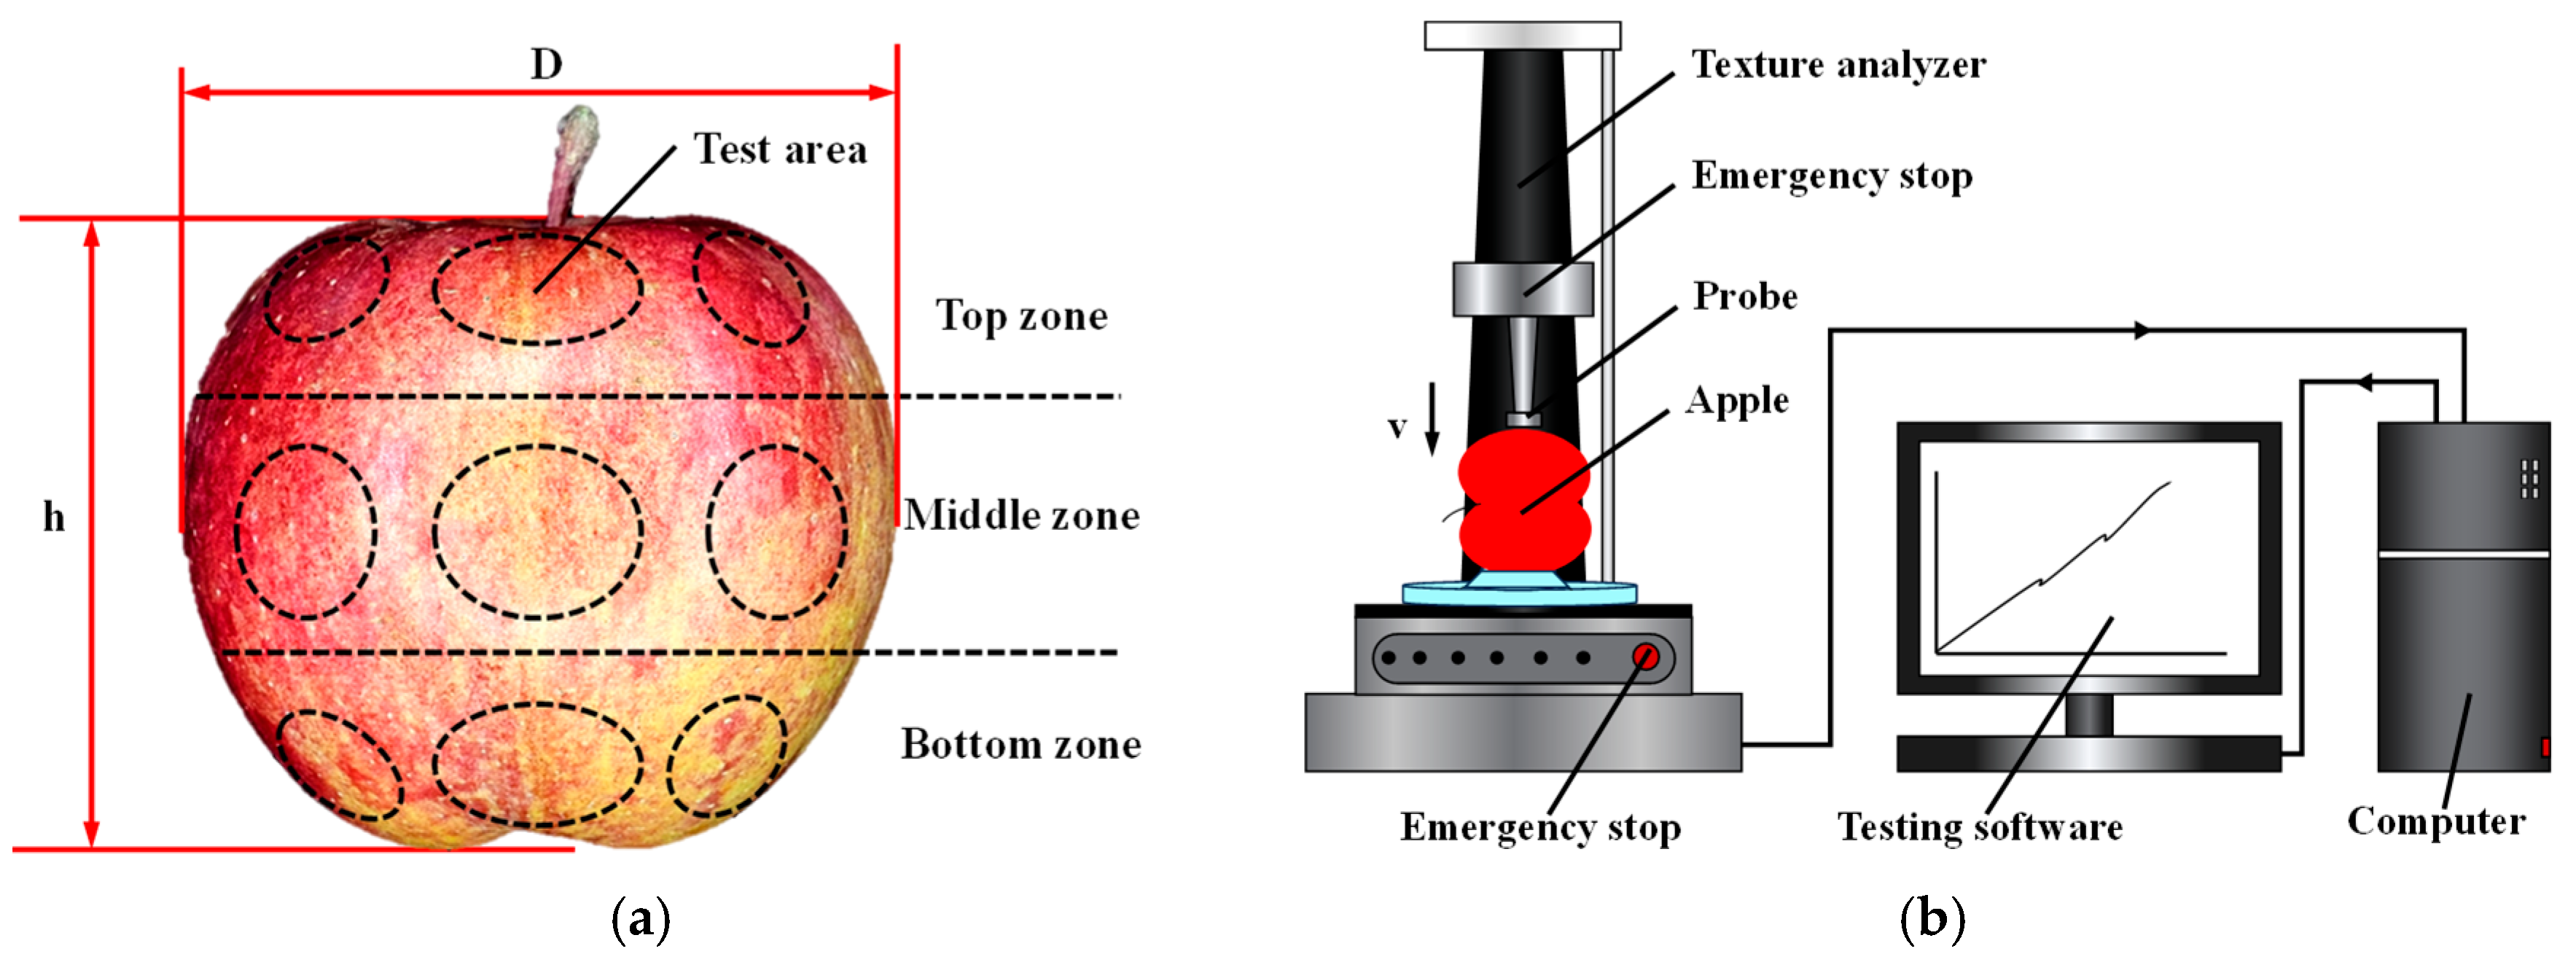
2.1. Measurement of Apple Skin Damage Force
2.1.1. Sample Preparation and Physical Parameter Measurement
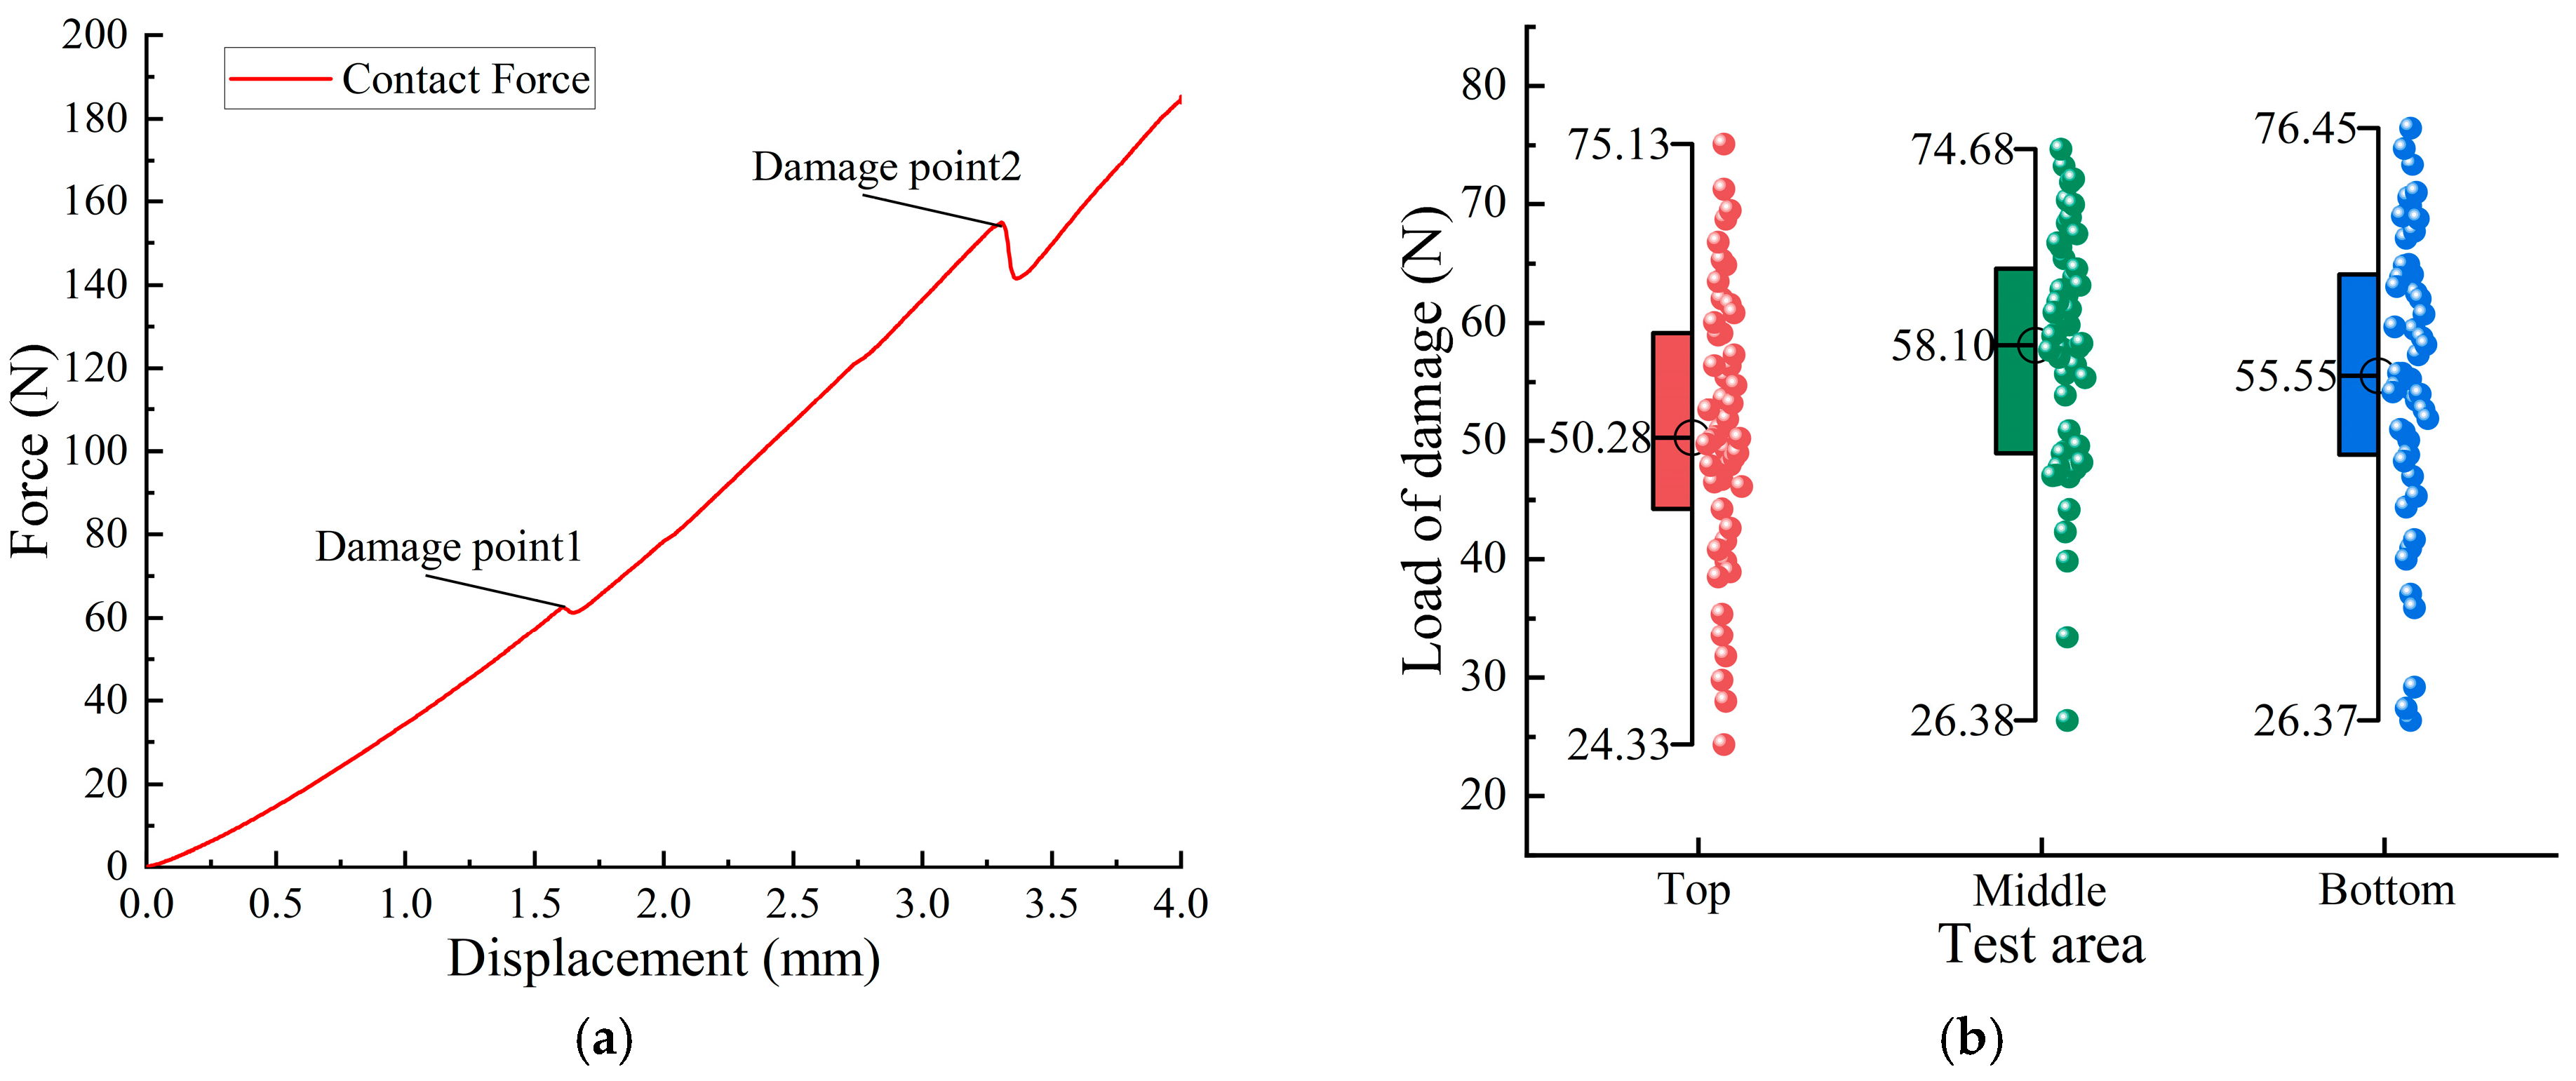
2.1.2. Measurement of Surface Damage Force in Three Regions of the Fruit
2.2. Design of the End-Effector
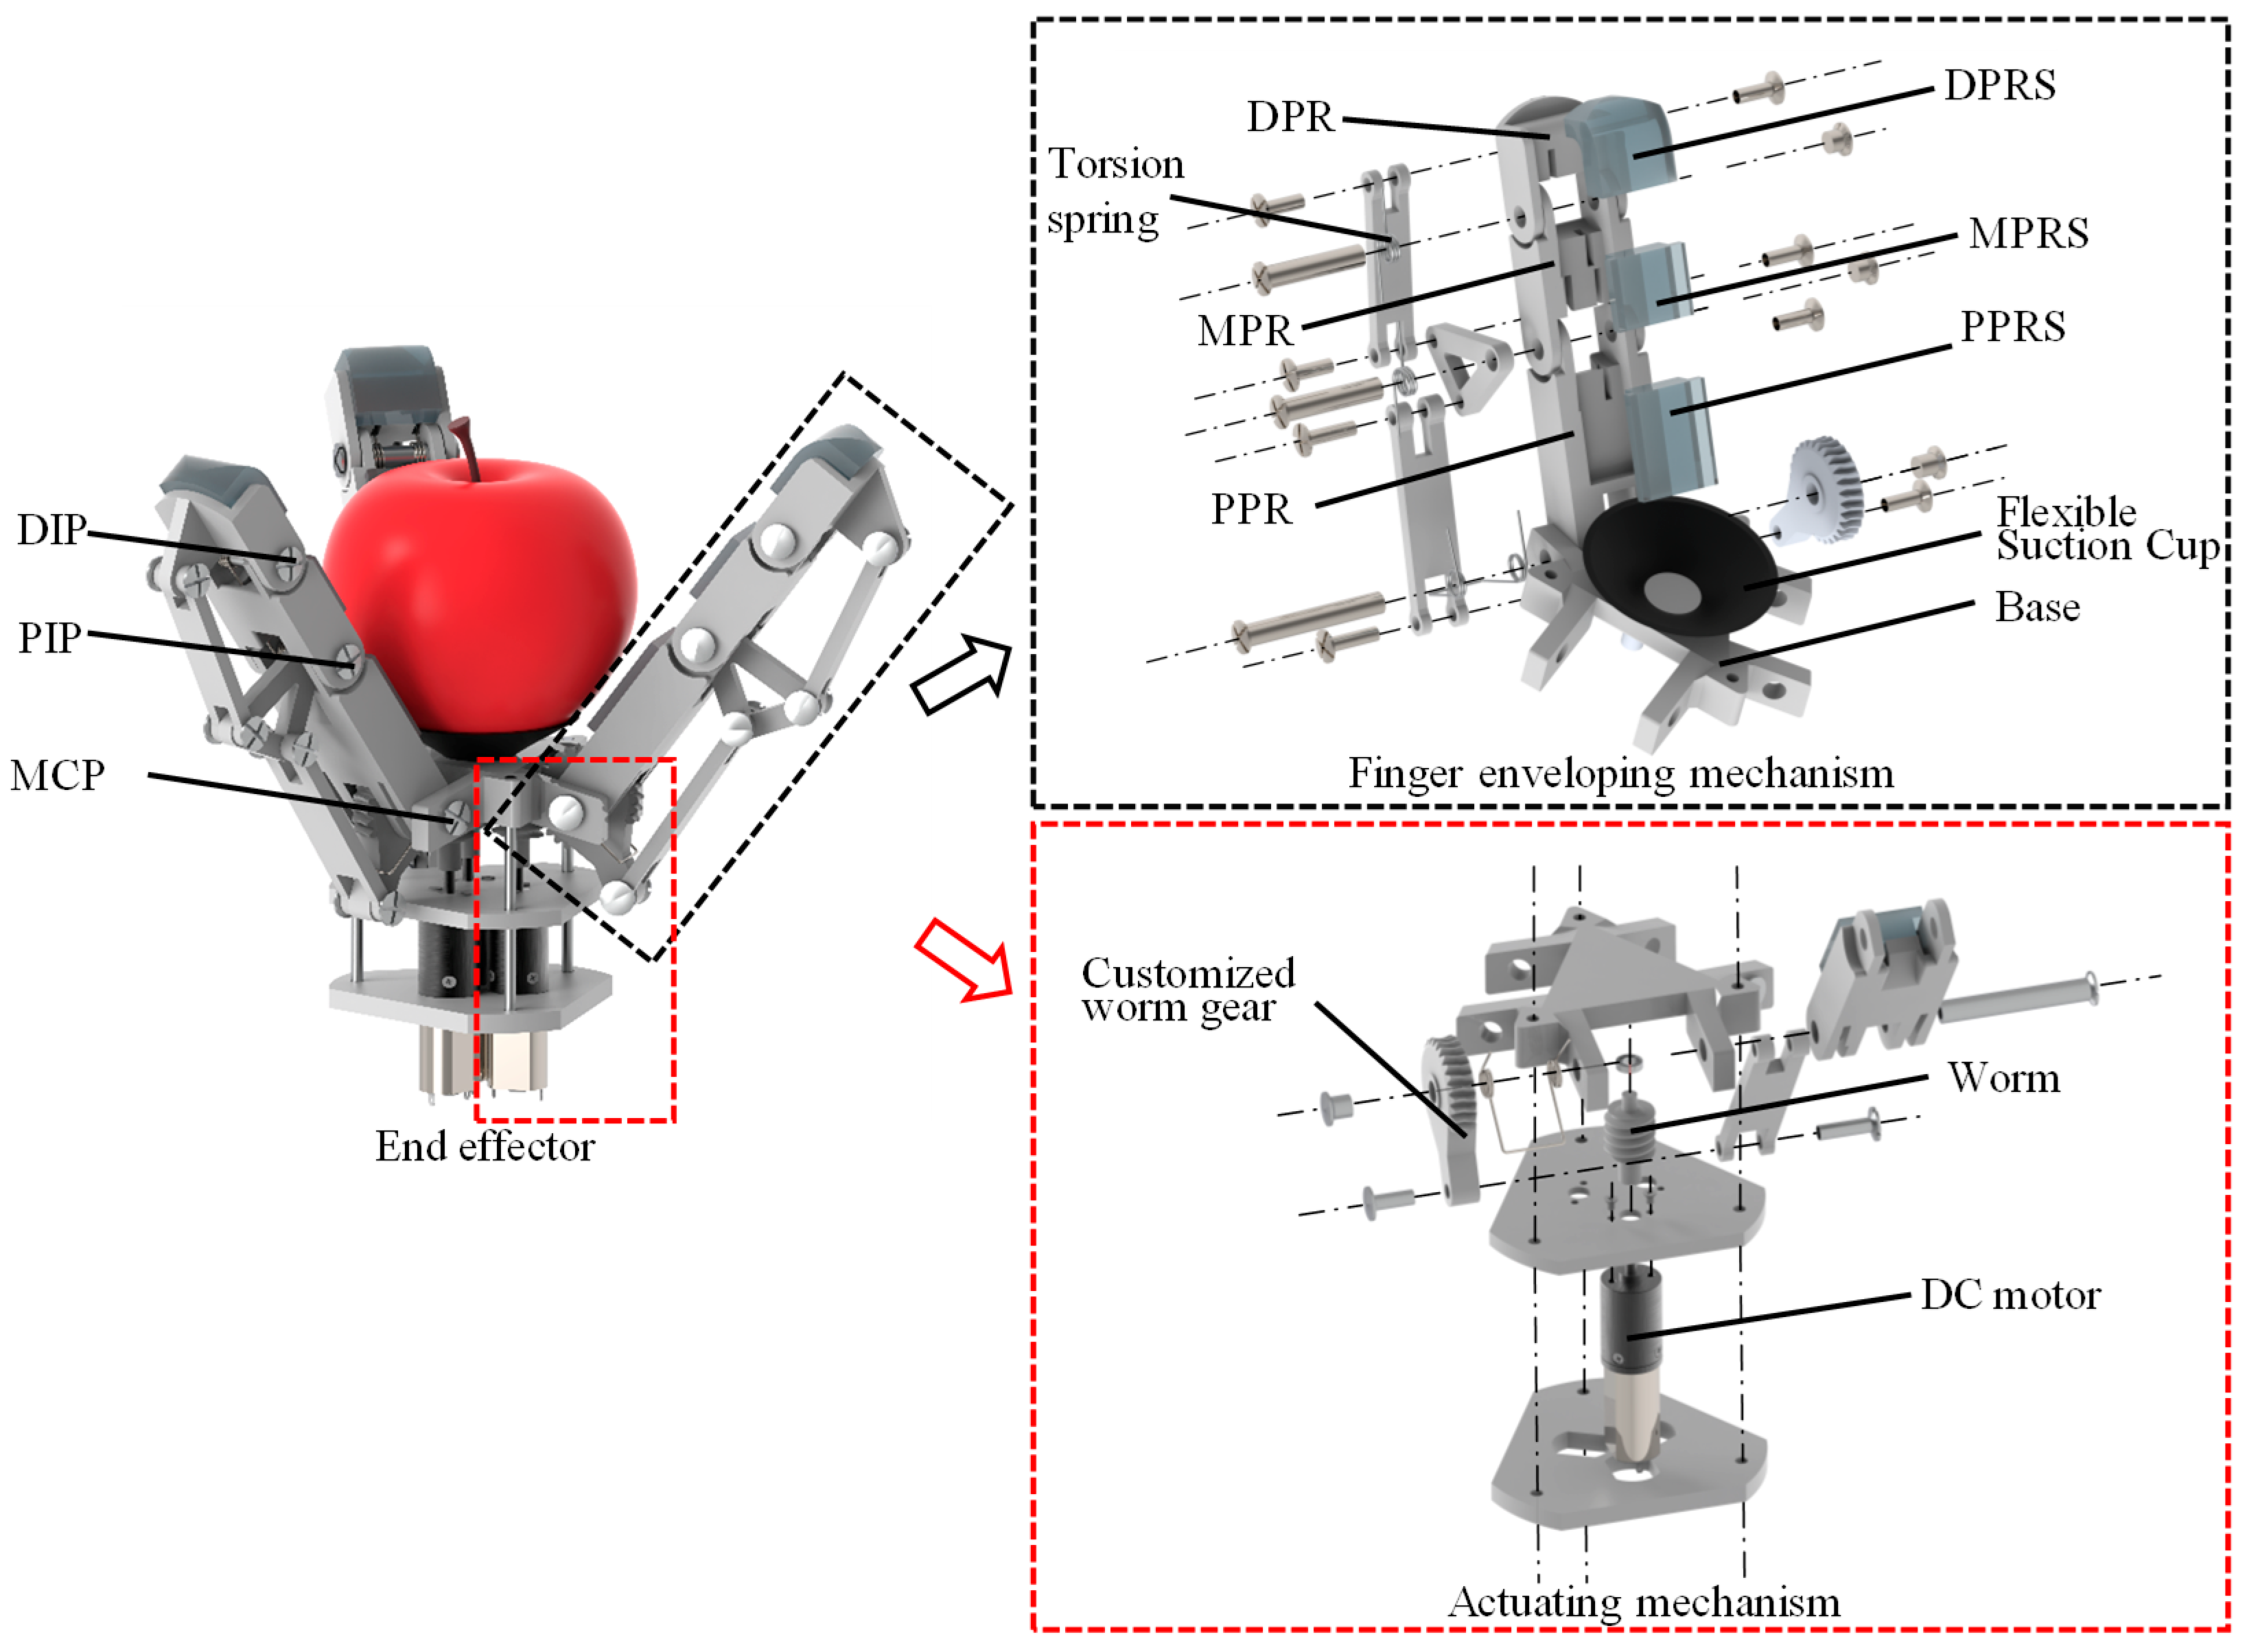
2.2.1. Structure Design of End-Effector
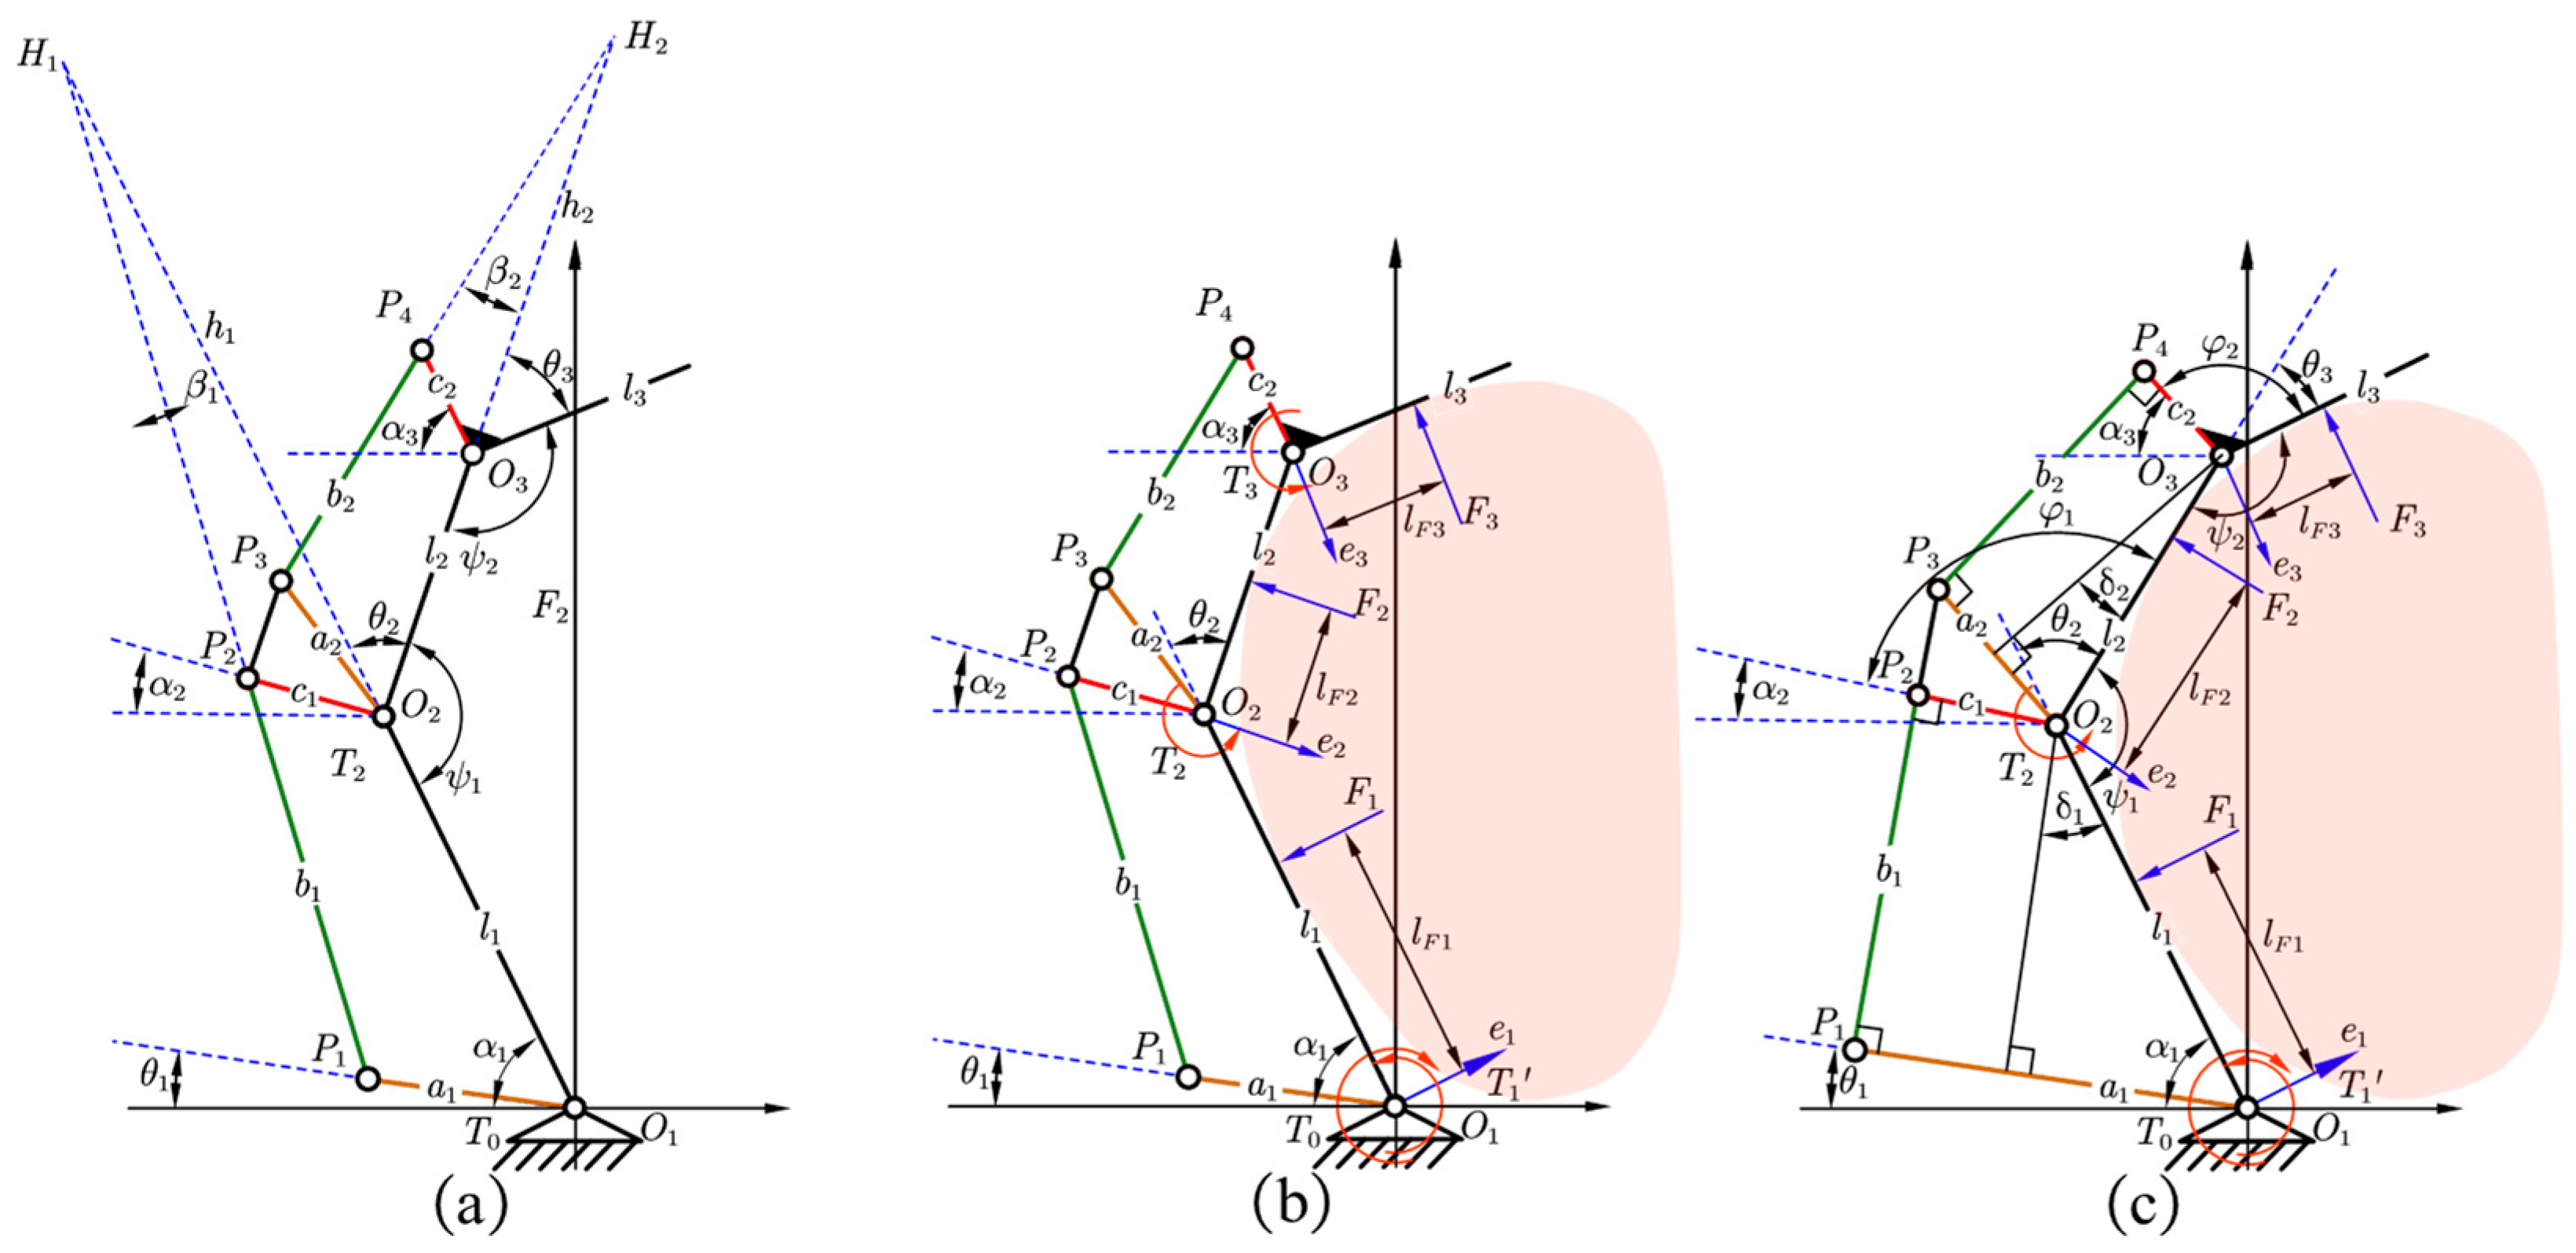
2.2.2. Static Analysis of the Finger Structure
2.3. Structural Optimization Based on Genetic Algorithm
2.4. Rigid–Flexible Coupled Dynamic Simulation Model of the End-Effector
2.4.1. Generation Method for the Flexible Body
2.4.2. Establishment of the Rigid–Flexible Coupled Simulation Model
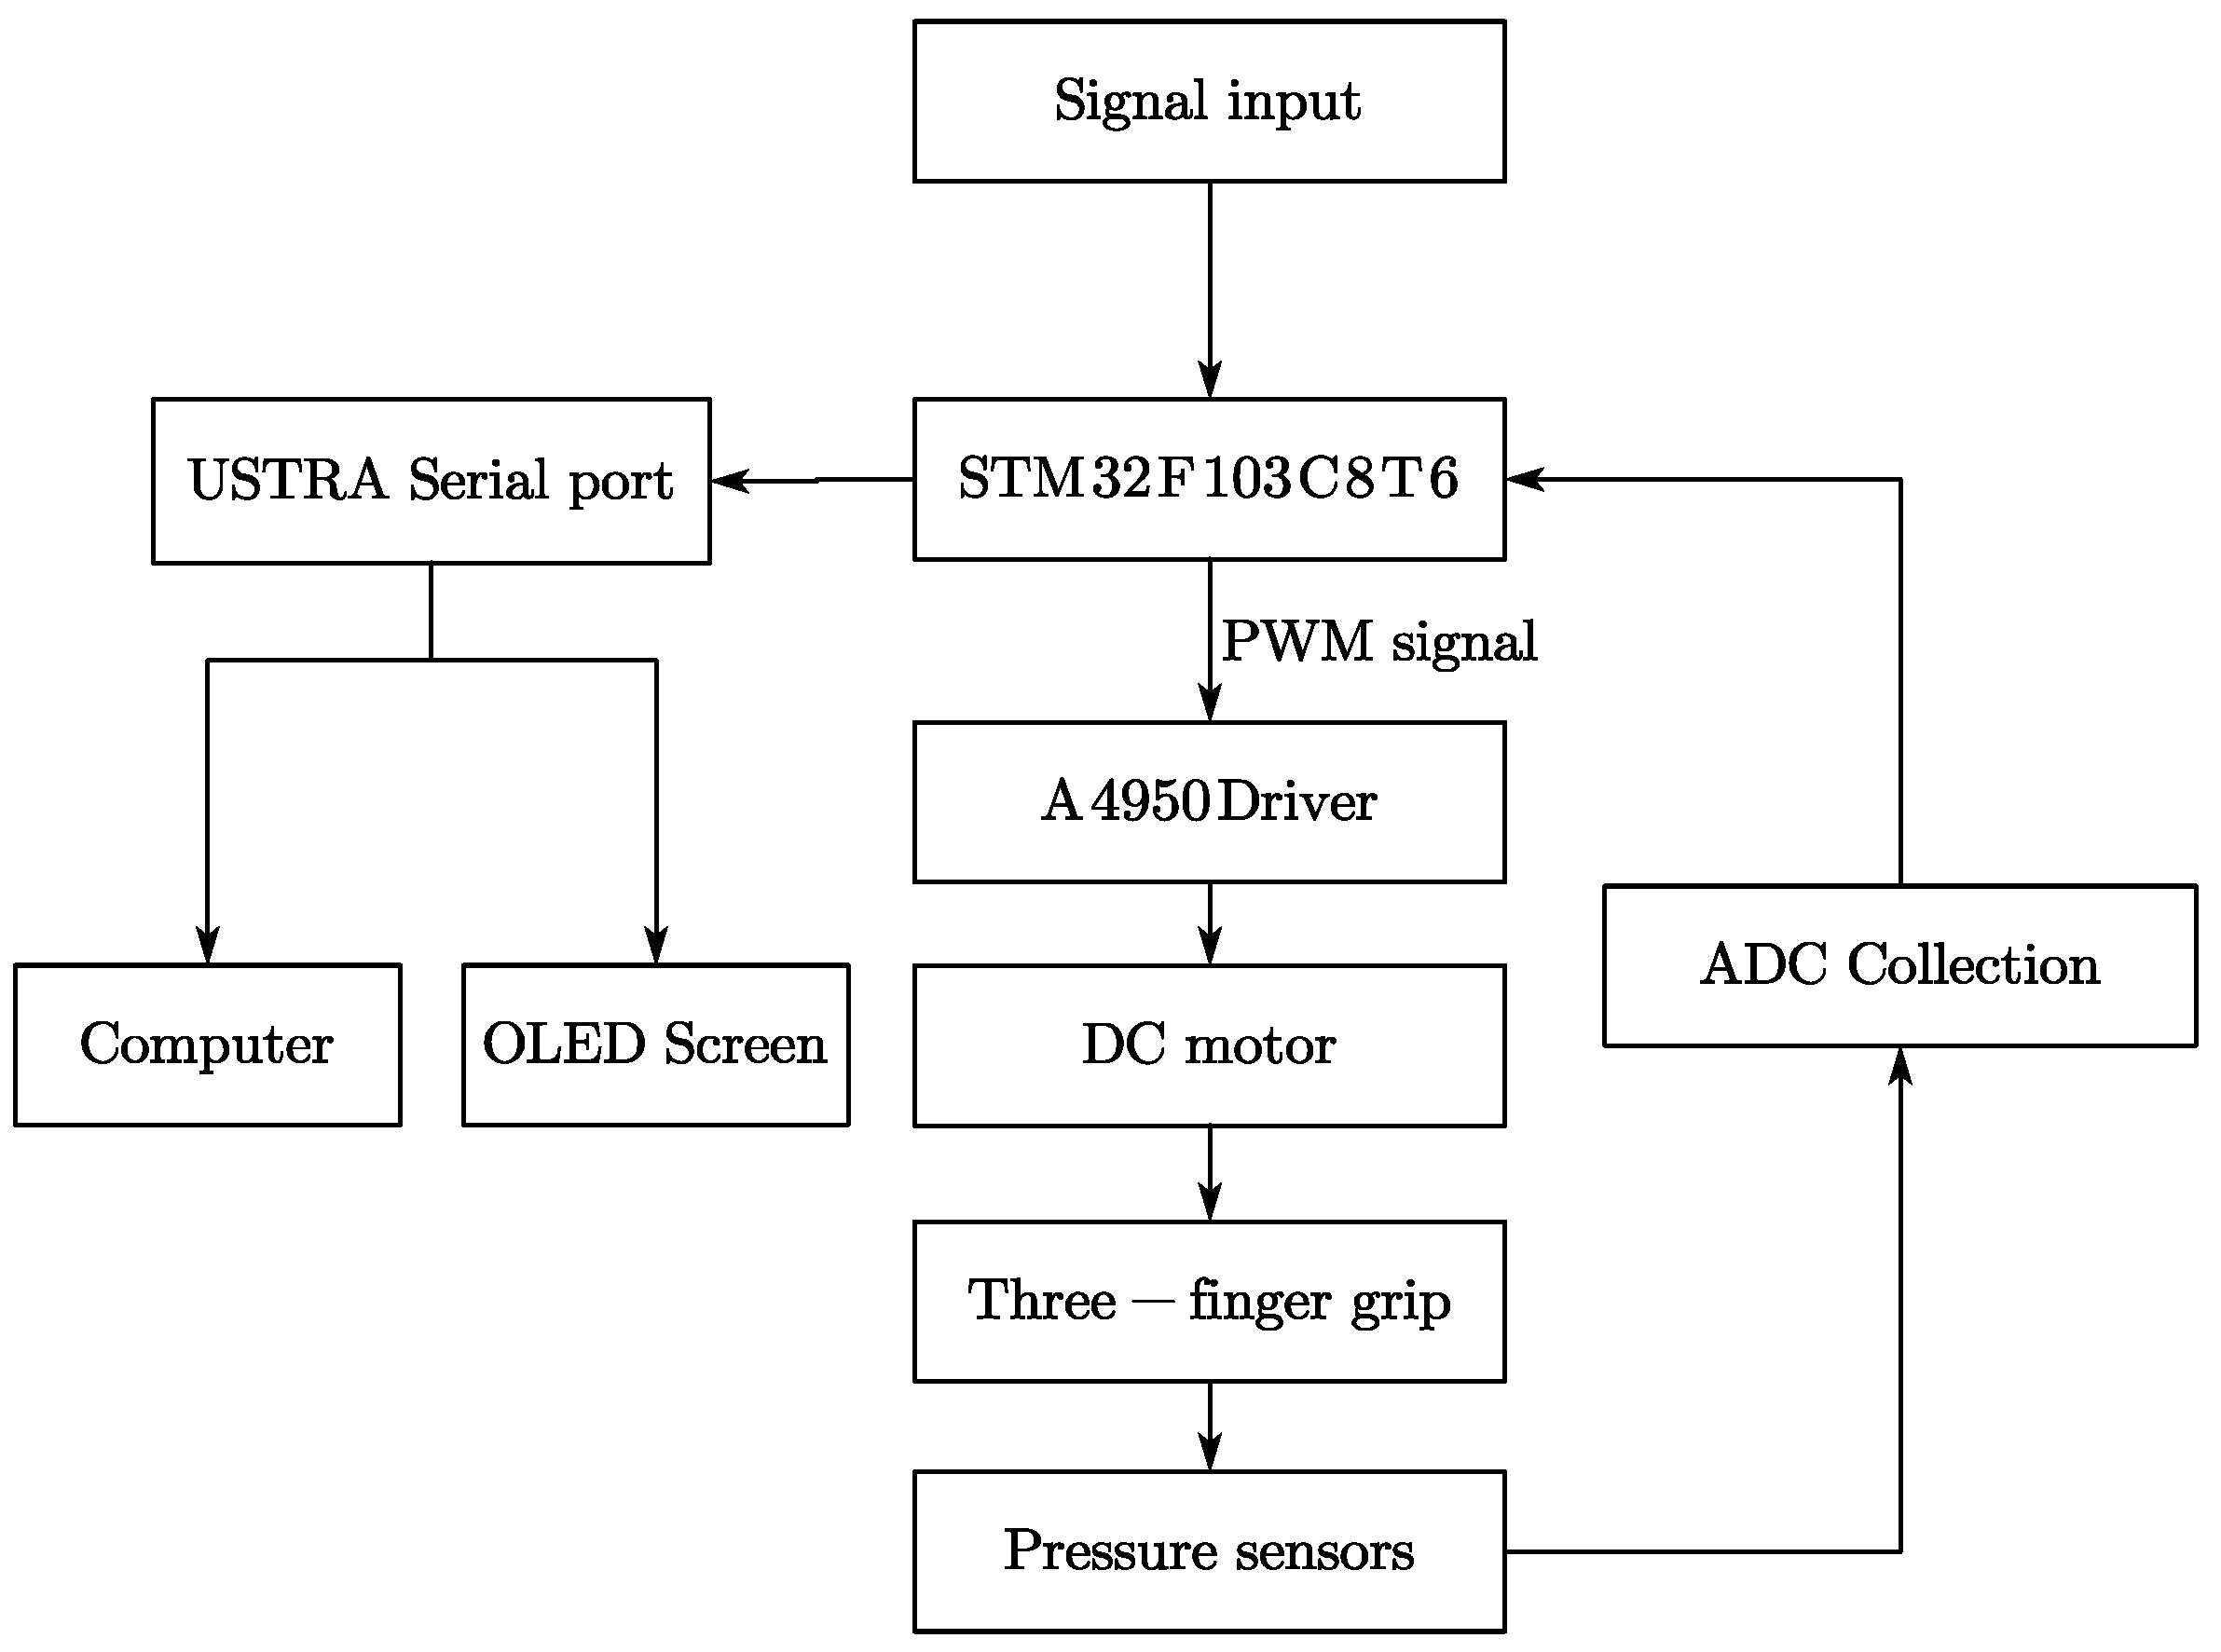
2.5. Experimental Platform
2.6. Low-Damage Apple Harvesting Technique and Mechanical Damage Assessment
2.6.1. Contact Force Constraints
2.6.2. Stress-Based Injury Assessment
3. Results and Discussion
3.1. Simulation Results
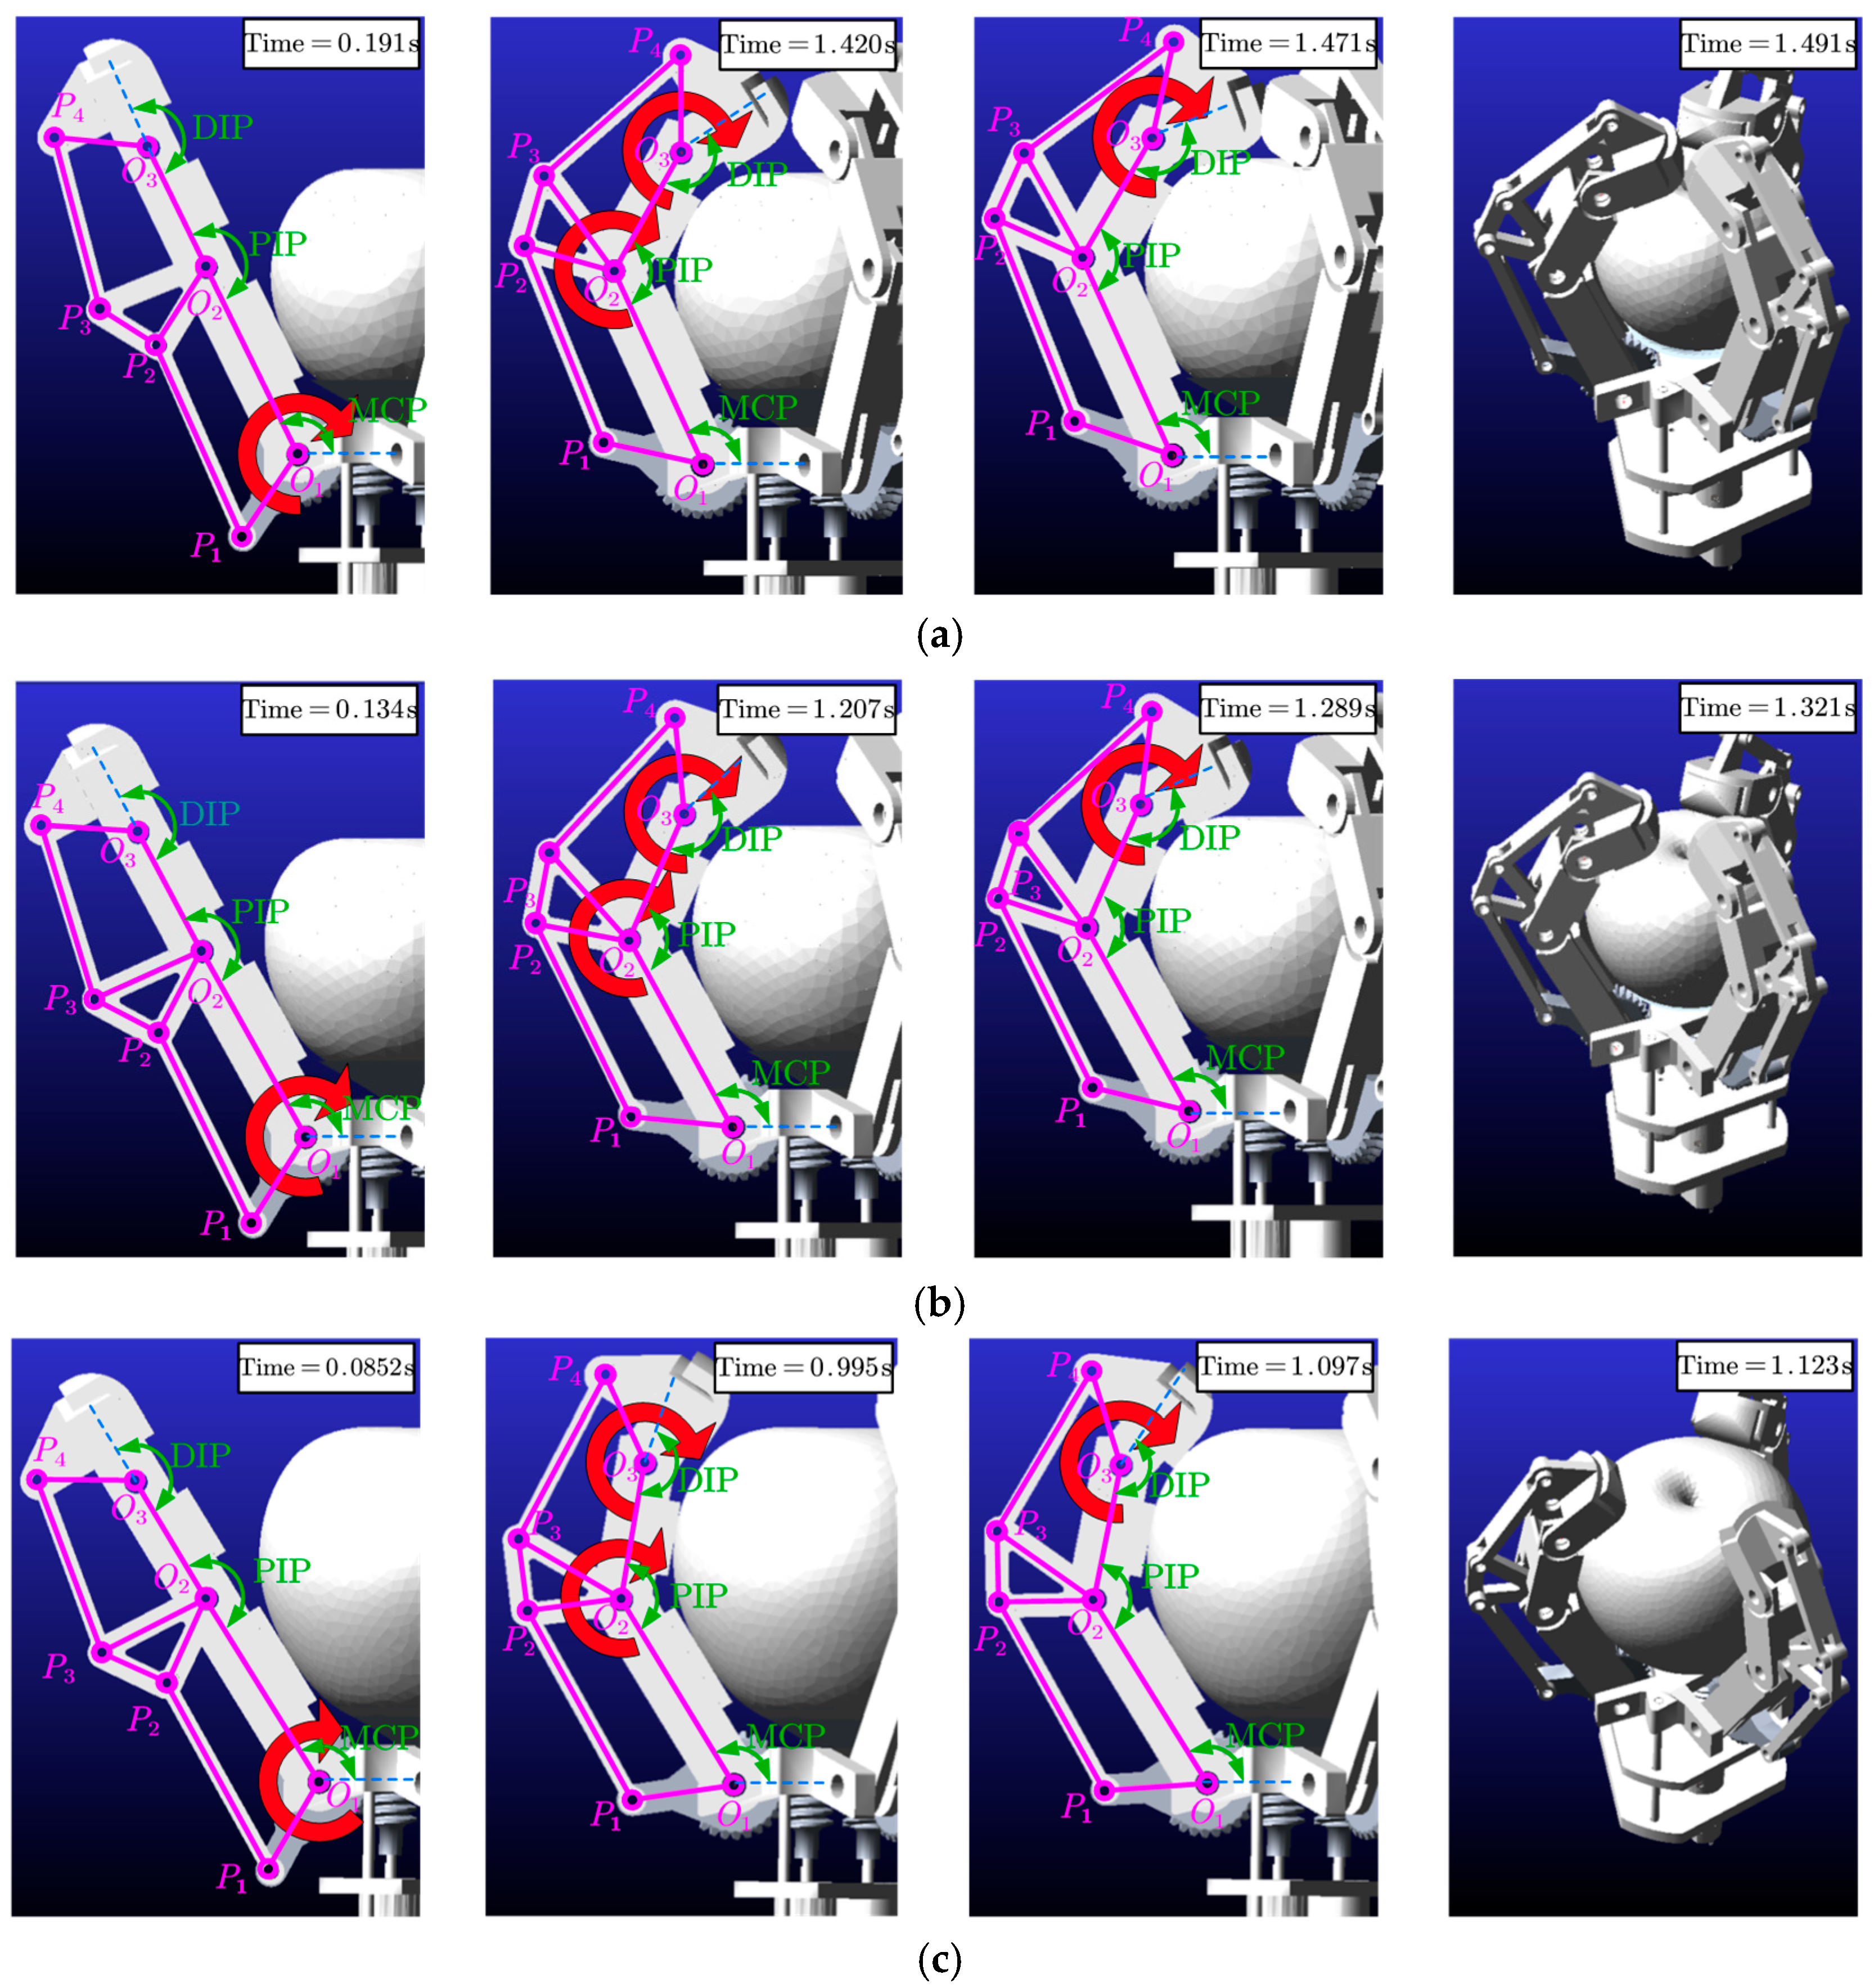
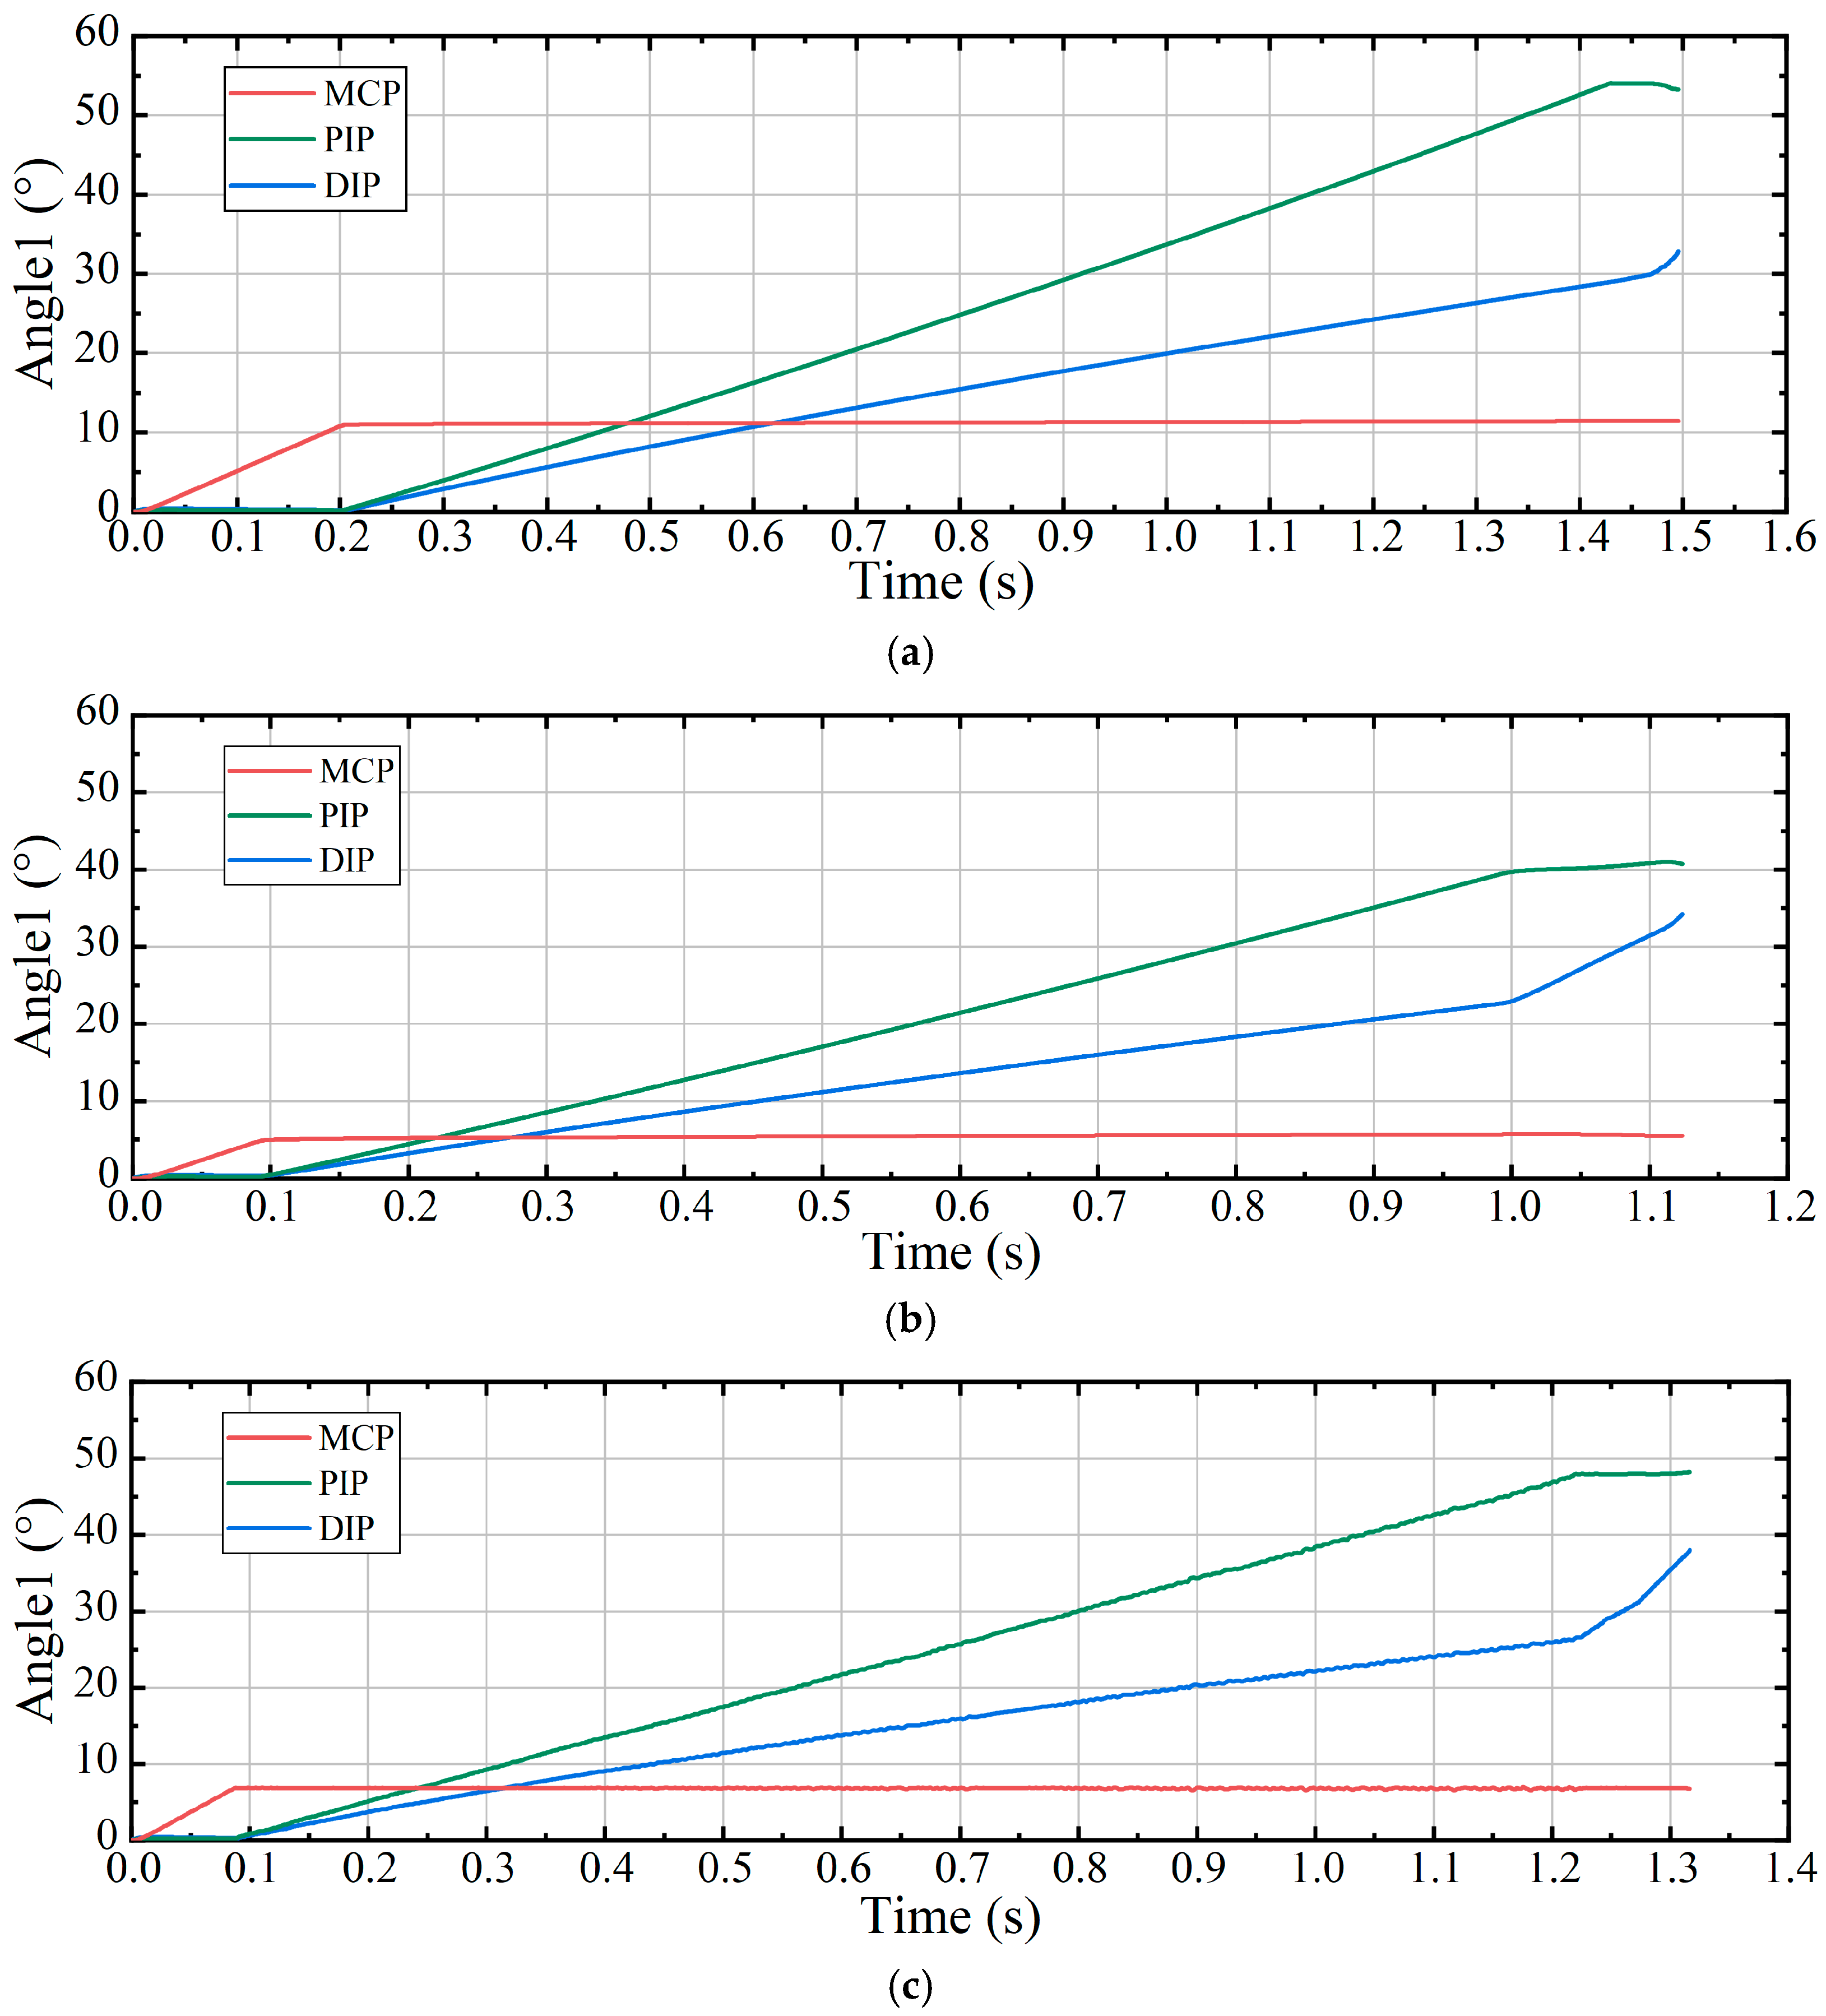
3.1.1. Dynamic Analysis of End-Effector Grasping
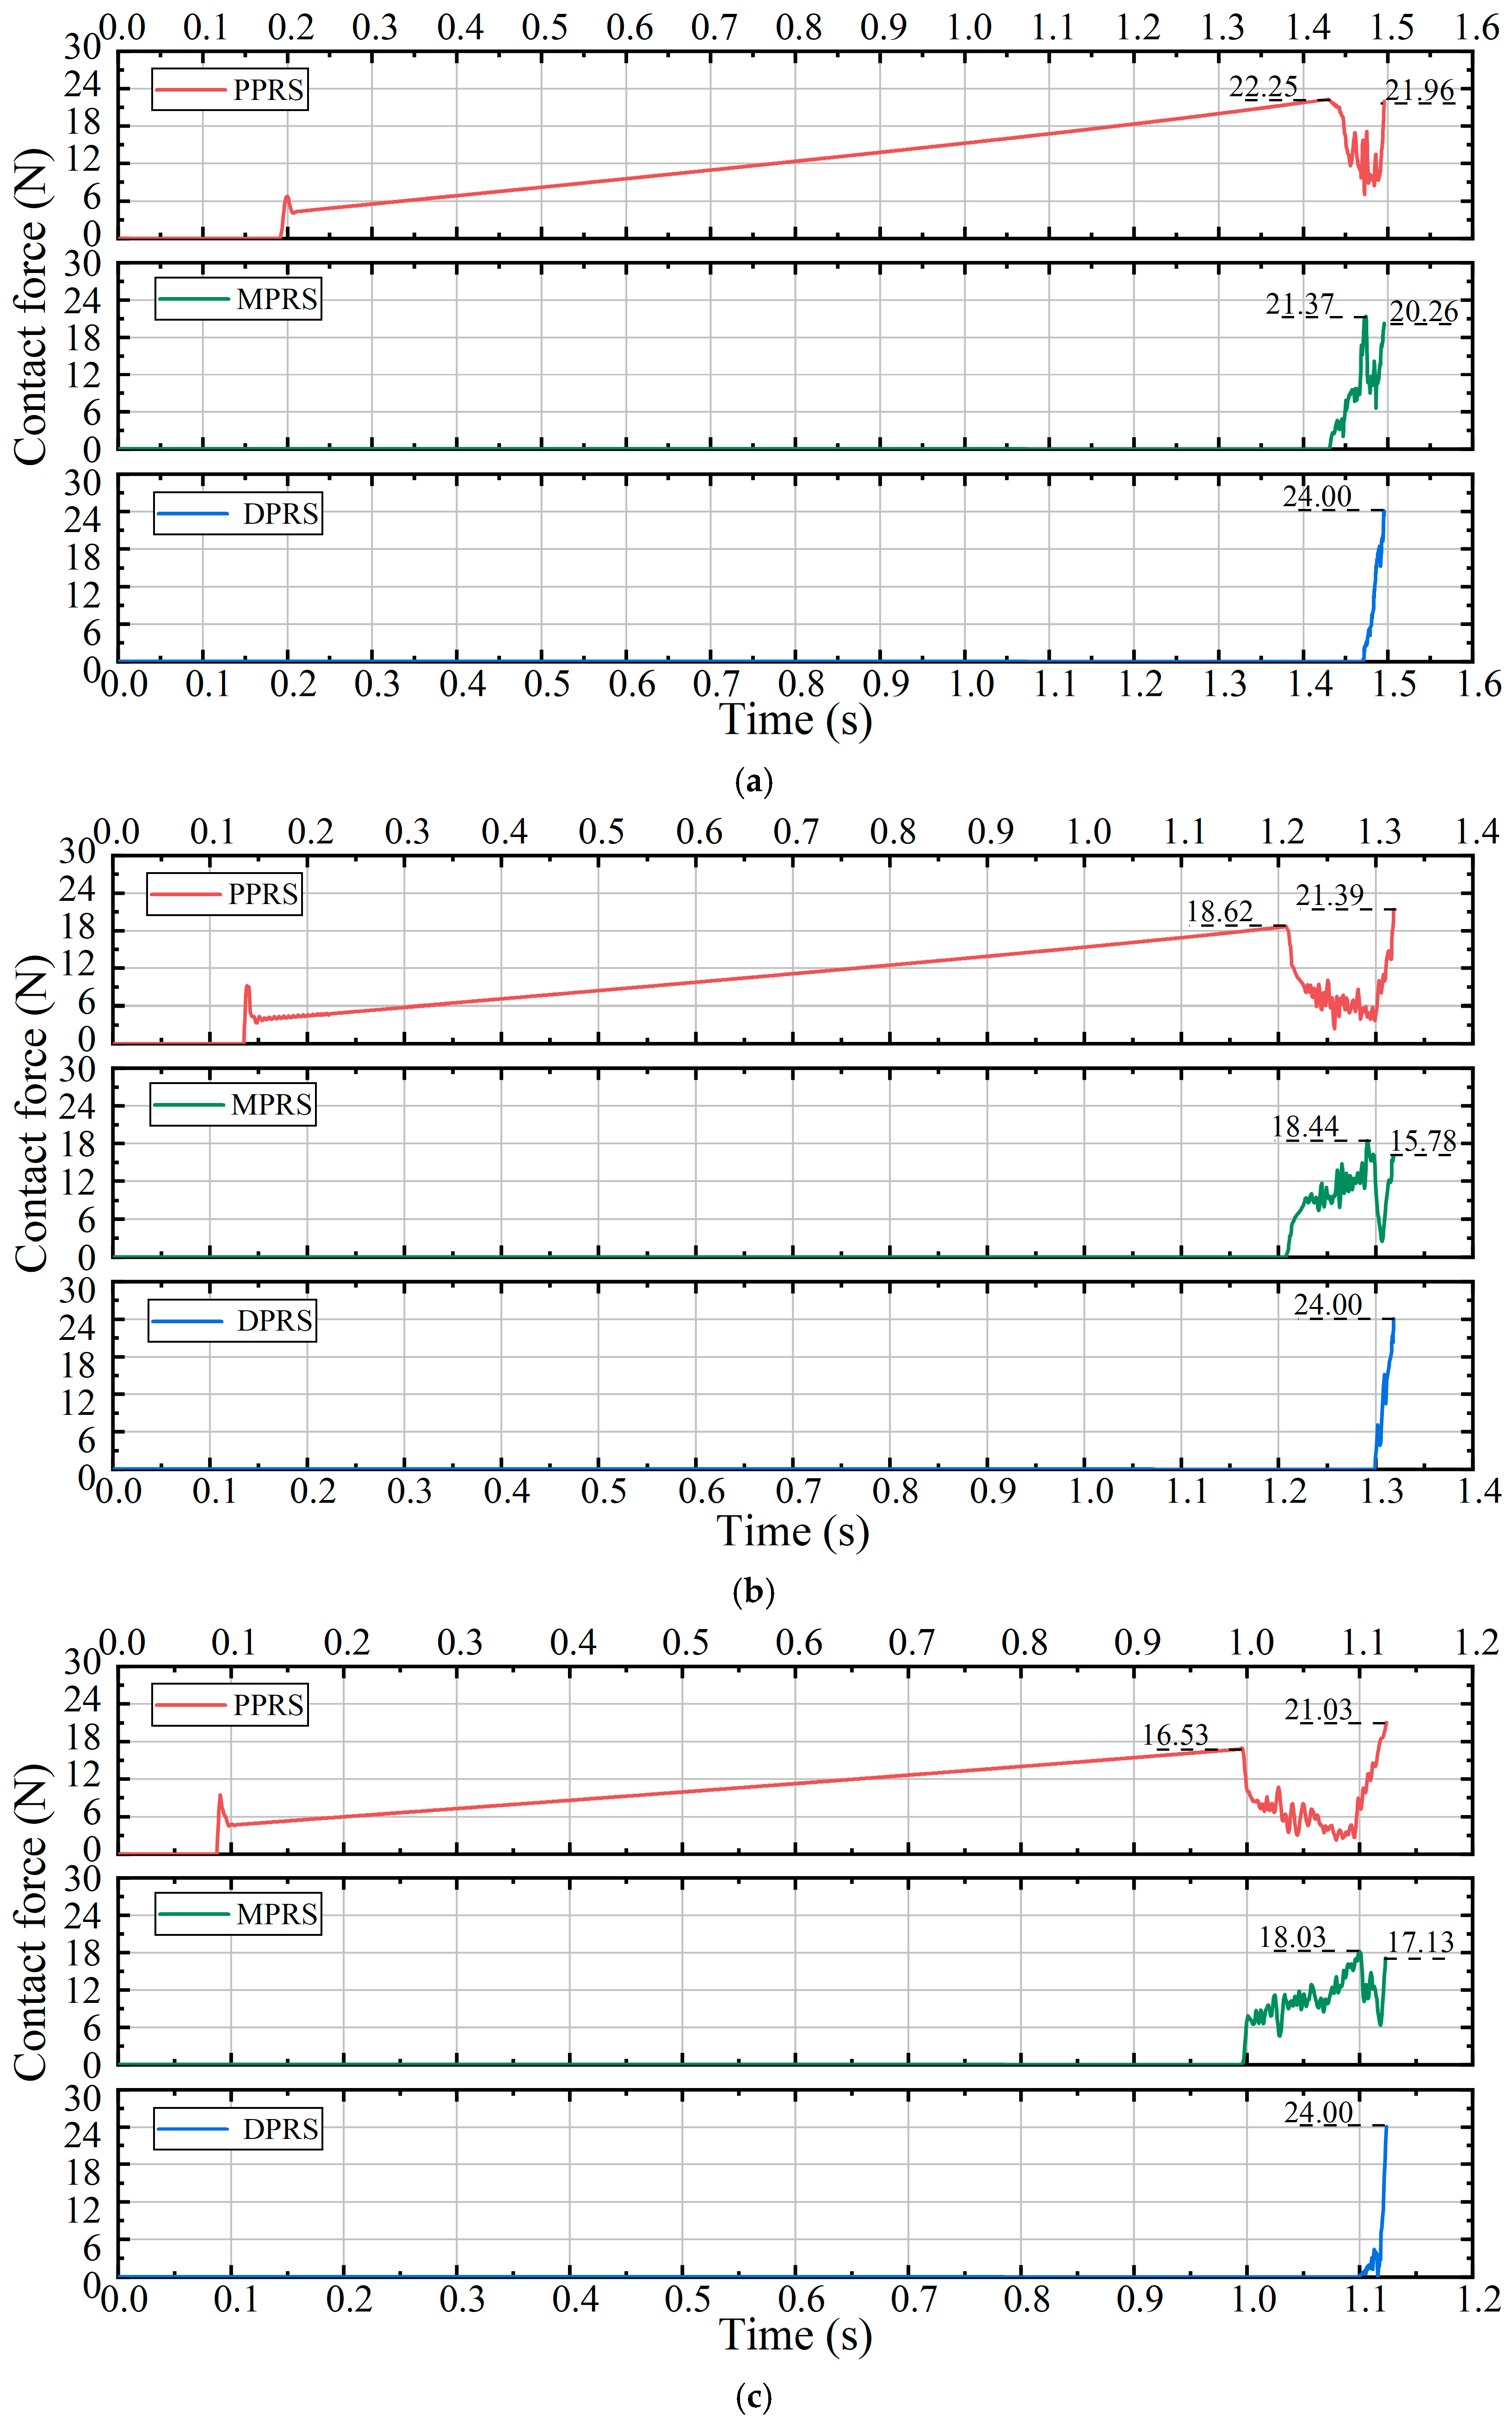
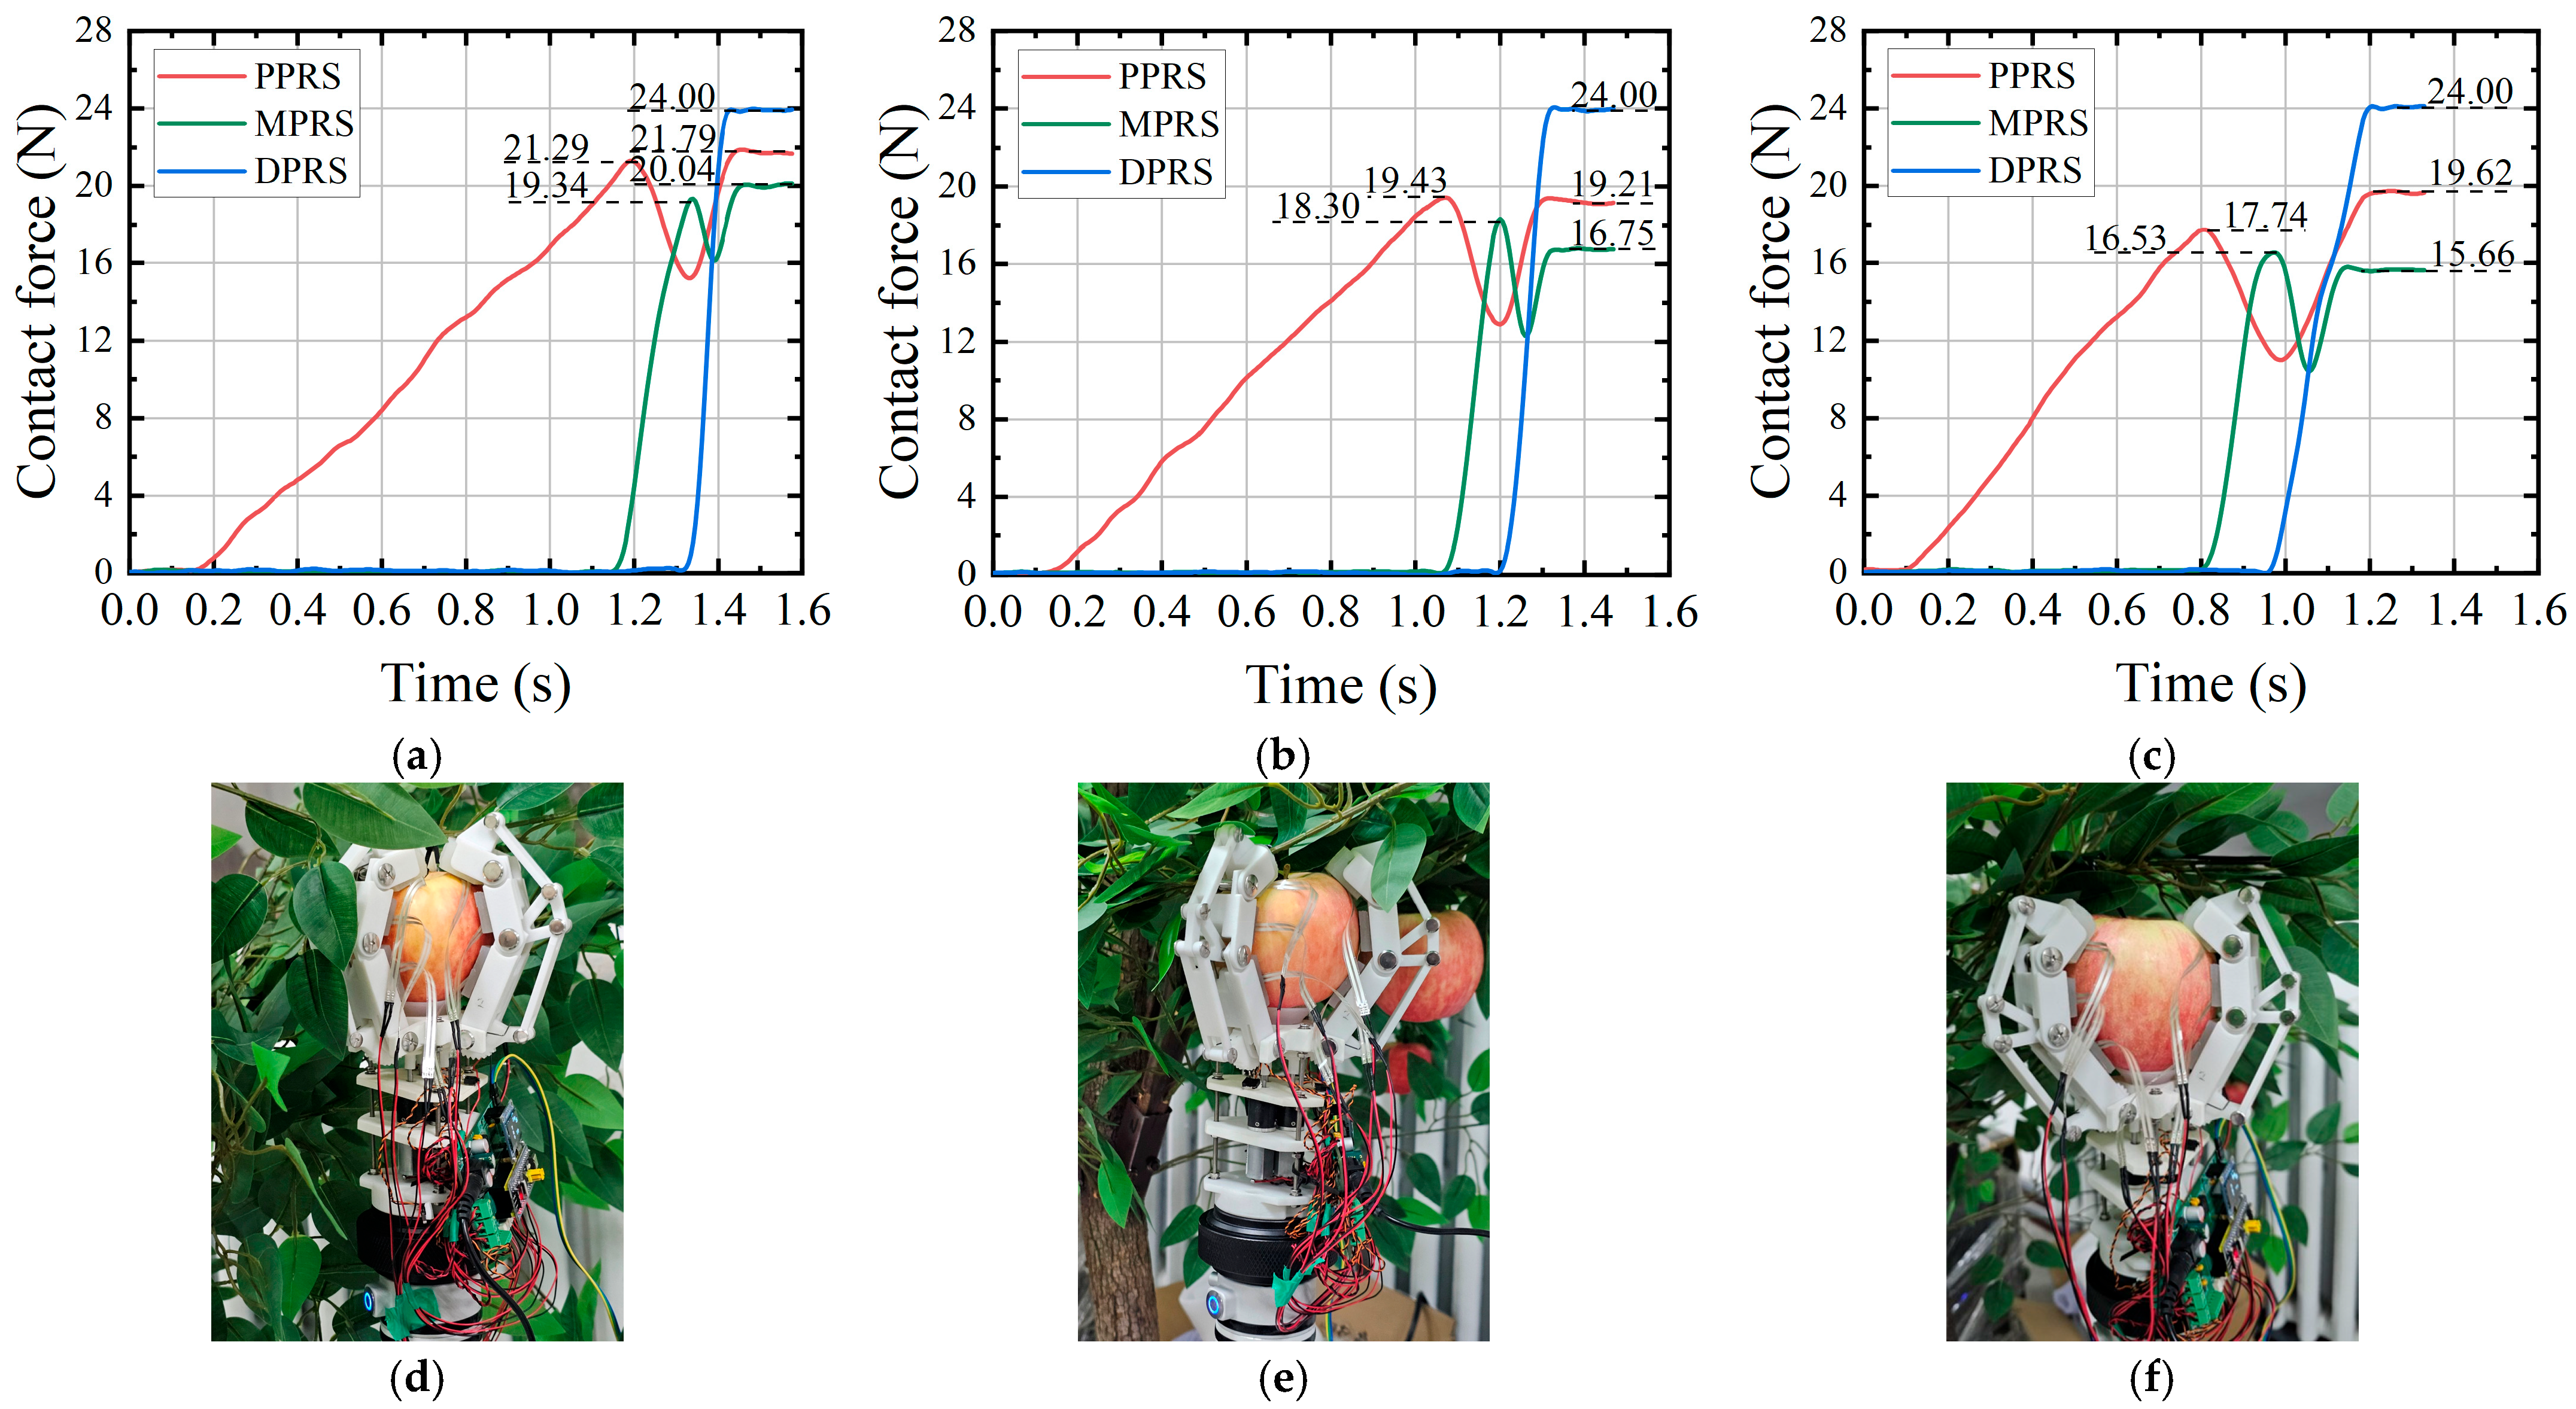
3.1.2. Analysis of Contact Forces During Grasping
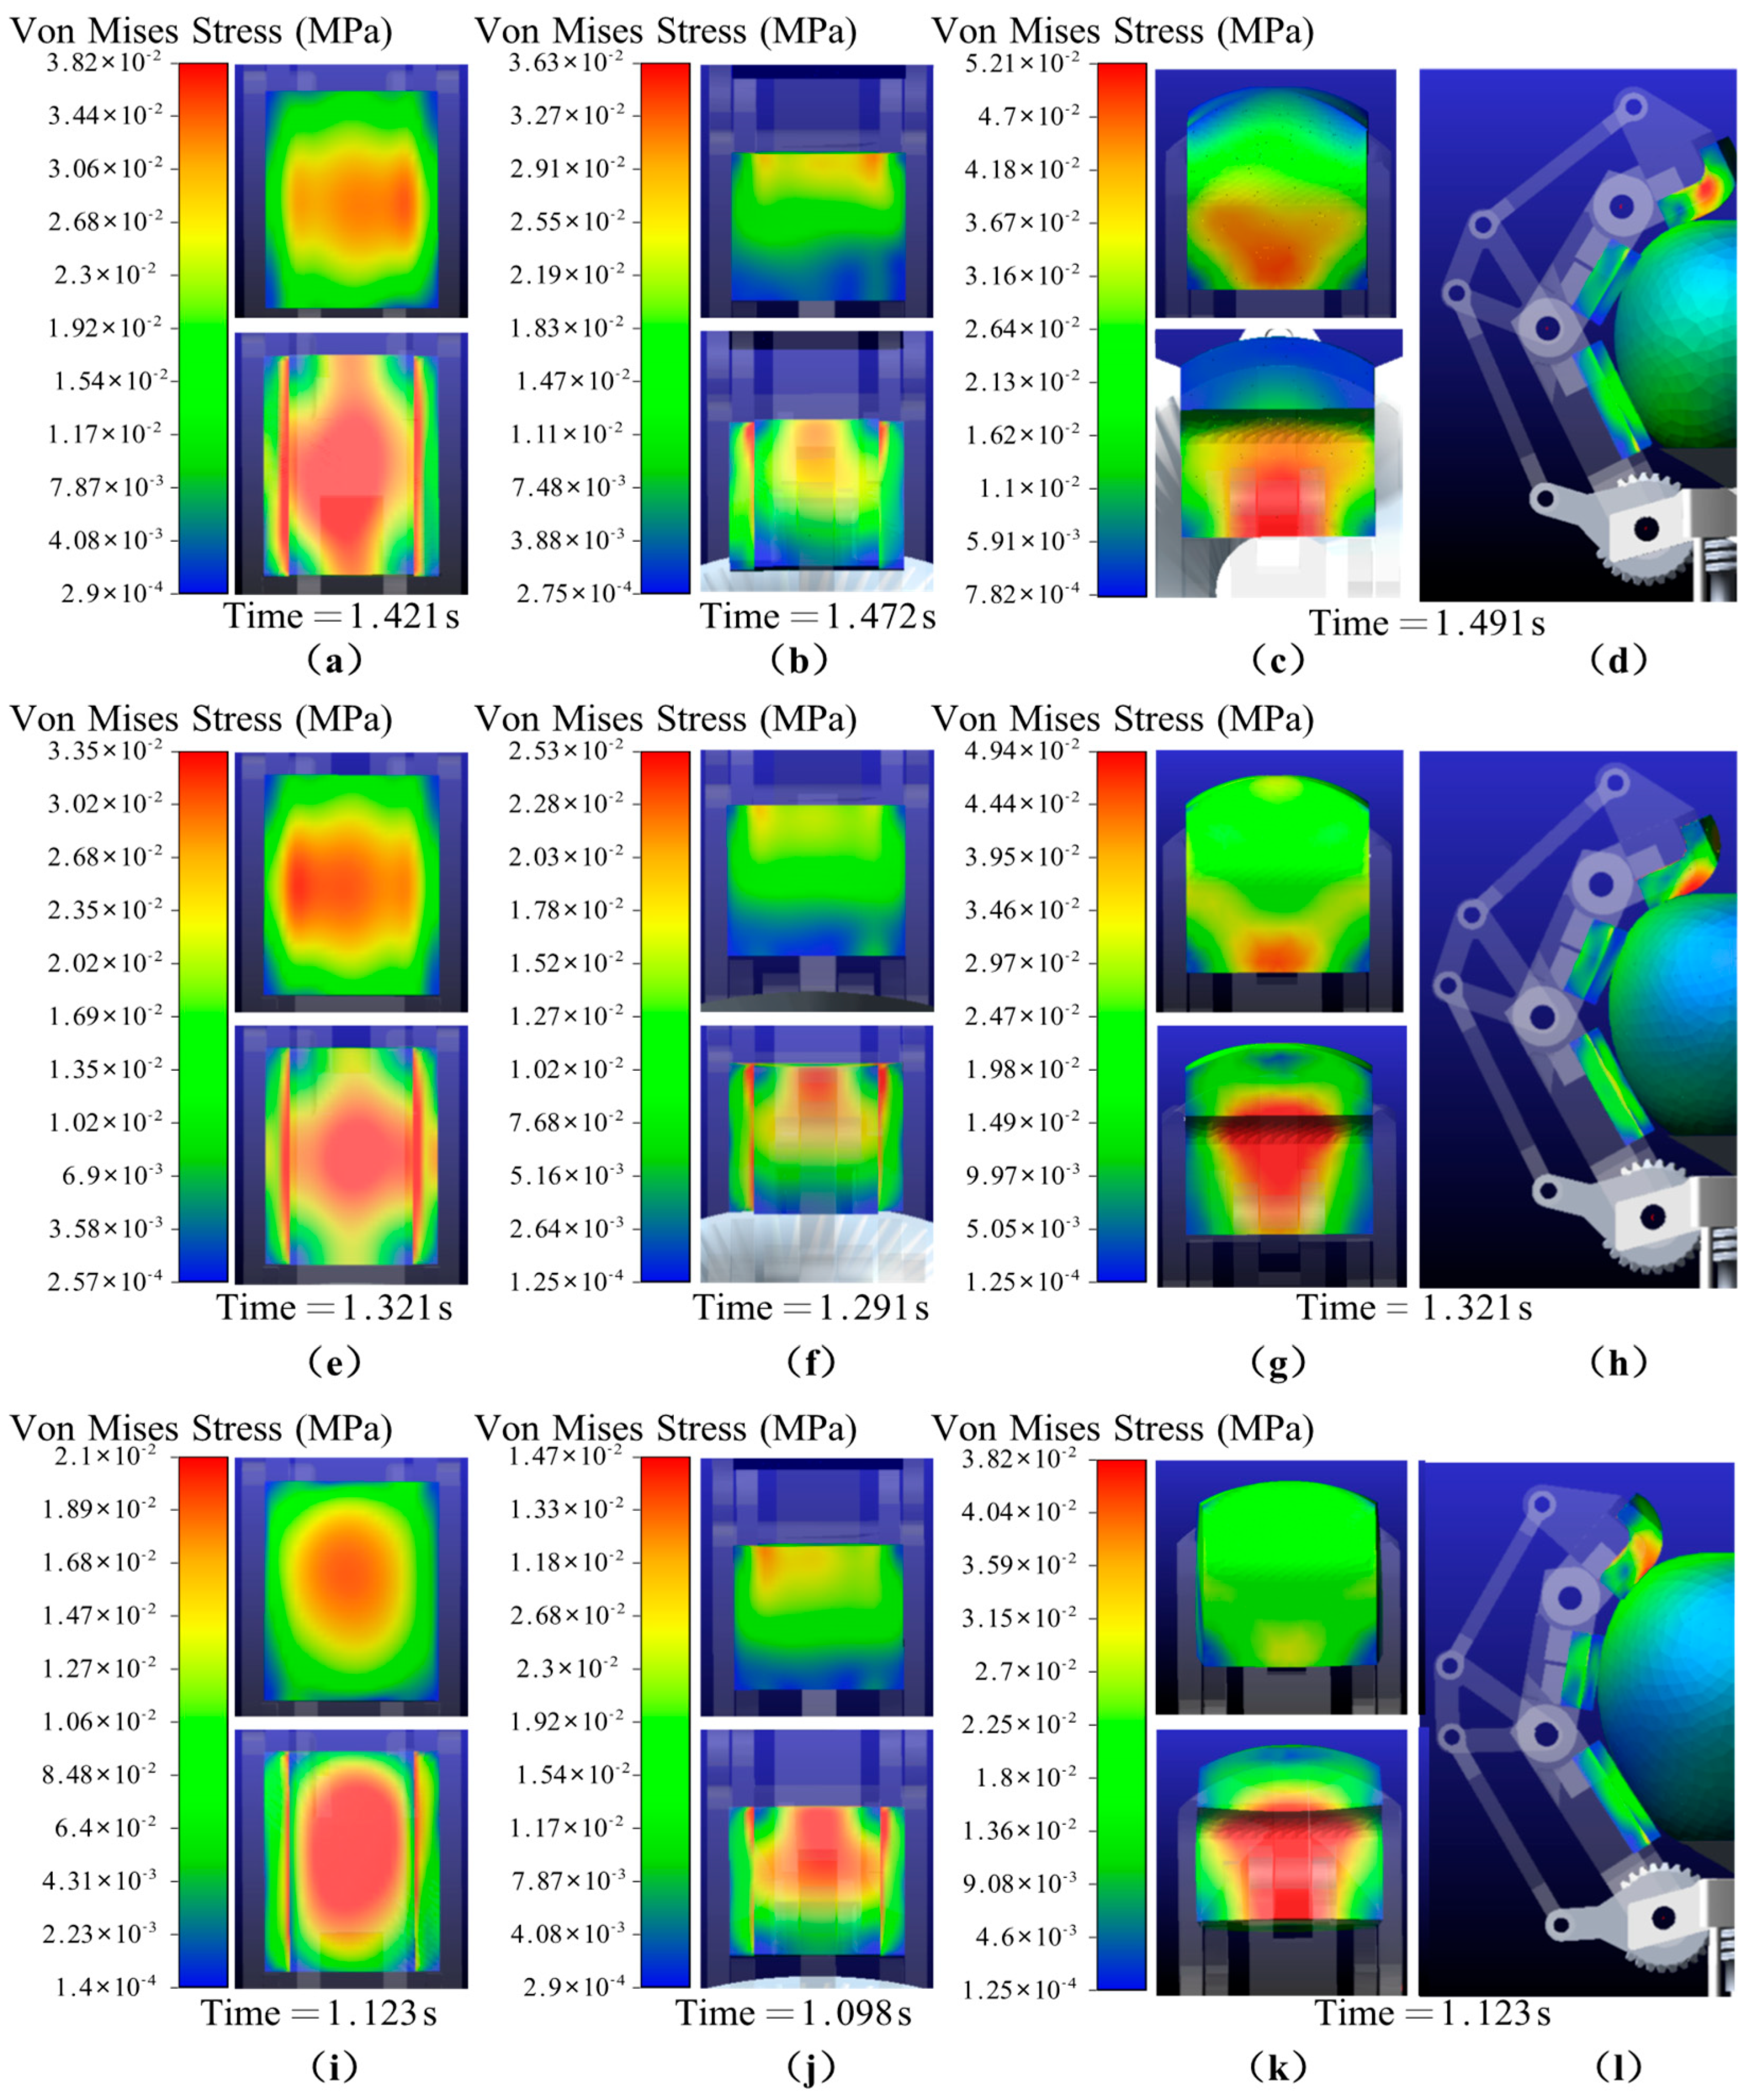
3.1.3. Analysis of Grasping Contact Stress
3.2. Laboratory Grasping Experiment
3.3. Performance Comparison
4. Conclusions
Author Contributions
Funding
Institutional Review Board Statement
Data Availability Statement
Conflicts of Interest
References
- Jeong, H.; Choi, C. Adaptive Supply Chain System Design for Fruit Crops under Climate Change. Systems 2023, 11, 514. [Google Scholar] [CrossRef] [Scilit]
- Miao, Y.; Zheng, J. Optimization design of compliant constant-force mechanism for apple picking actuator. Comput. Electron. Agric. 2020, 170, 105232. [Google Scholar] [CrossRef] [Scilit]
- Bao, X.; Ma, Z.; Ma, X.; Li, Y.; Ren, M.; Li, S. Design and Experiment of a Citrus Picking Robot under Natural Conditions in Hilly Orchards. Trans. Chin. Soc. Agric. Mach. 2024, 55, 124–135. [Google Scholar]
- Ji, W.; He, G.; Xu, B.; Zhang, H.; Yu, X. A new picking pattern of a flexible three-fingered end-effector for apple harvesting robot. Agriculture 2024, 14, 102. [Google Scholar] [CrossRef] [Scilit]
- Jia, W.; Tian, Y.; Luo, R.; Zhang, Z.; Lian, J.; Zheng, Y. Detection and segmentation of overlapped fruits based on optimized mask R-CNN application in apple harvesting robot. Comput. Electron. Agric. 2020, 172, 105380. [Google Scholar] [CrossRef] [Scilit]
- Graham, S.S.; Zong, W.; Feng, J.; Tang, S. Design and testing of a kiwifruit harvester end-effector. Trans. ASABE 2018, 61, 45–51. [Google Scholar] [CrossRef] [Scilit]
- Bac, C.W.; Hemming, J.; Van Tuijl, B.; Barth, R.; Wais, E.; van Henten, E.J. Performance evaluation of a harvesting robot for sweet pepper. J. Field Robot. 2017, 34, 1123–1139. [Google Scholar] [CrossRef] [Scilit]
- Kondo, N.; Yamamoto, K.; Shimizu, H.; Yata, K.; Kurita, M.; Shiigi, T.; Monta, M.; Nishizu, T. A machine vision system for tomato cluster harvesting robot. Eng. Agric. Environ. Food 2009, 2, 60–65. [Google Scholar] [CrossRef] [Scilit]
- Han, C.; Lv, J.; Dong, C.; Li, J.; Luo, Y.; Wu, W.; Abdeen, M.A. Classification, advanced technologies, and typical applications of end-effector for fruit and vegetable picking robots. Agriculture 2024, 14, 1310. [Google Scholar] [CrossRef] [Scilit]
- Zhang, K.; Lammers, K.; Chu, P.; Li, Z.; Lu, R. System design and control of an apple harvesting robot. Mechatronics 2021, 79, 102644. [Google Scholar] [CrossRef] [Scilit]
- Han, S.; Zhang, Z.; Zhang, H.; Zhang, Y.; Wang, Z. Design and Simulation Analysis of the End-Effector for Round Fruit Picking Robot. J. Mach. Des. 2019, 36, 82–85. [Google Scholar]
- Ma, Z.; Yan, H.; Tai, L.; Du, X. Optimization Design and Test of Occlusal-type Citrus Picking End-effector. Trans. Chin. Soc. Agric. Mach. 2024, 55, 106–115+125. [Google Scholar]
- Wang, Y.; Fang, S.; Zhao, Z.; Ma, J.; Xu, H. Design and Experiment of End-Effector for Citrus Picking Robot. Chin. Agric. Sci. Bull. 2018, 34, 69–77. [Google Scholar]
- Hu, G.; Chen, C.; Chen, J.; Sun, L.; Sugirbay, A.; Chen, Y.; Jin, H.; Zhang, S.; Bu, L. Simplified 4-DOF manipulator for rapid robotic apple harvesting. Comput. Electron. Agric. 2022, 199, 107177. [Google Scholar] [CrossRef] [Scilit]
- Valk, T.A.; Mouton, L.J.; Otten, E.; Bongers, R.M. Synergies reciprocally relate end-effector and joint-angles in rhythmic pointing movements. Sci. Rep. 2019, 9, 17378. [Google Scholar] [CrossRef] [Scilit]
- Fujinaga, T.; Yasukawa, S.; Ishii, K. Development and evaluation of a tomato fruit suction cutting device. In Proceedings of the 2021 IEEE/SICE International Symposium on System Integration (SII), Iwaki, Japan, 11–14 January 2021; pp. 628–633. [Google Scholar]
- Zhou, K.; Xia, L.; Liu, J.; Qian, M.; Pi, J. Design of a flexible end-effector based on characteristics of tomatoes. Int. J. Agric. Biol. Eng. 2022, 15, 13–24. [Google Scholar] [CrossRef] [Scilit]
- Liu, J.; Li, P.; Li, Z. A multi-sensory end-effector for spherical fruit harvesting robot. In Proceedings of the 2007 IEEE International Conference on Automation and Logistics, Jinan, China, 18–21 August 2007; pp. 258–262. [Google Scholar]
- Jun, J.; Kim, J.; Seol, J.; Kim, J.; Son, H.I. Towards an efficient tomato harvesting robot: 3D perception, manipulation, and end-effector. IEEE Access 2021, 9, 17631–17640. [Google Scholar] [CrossRef] [Scilit]
- De Luca, A.; Mattone, R.; Oriolo, G. Steering a class of redundant mechanisms through end-effector generalized forces. IEEE Trans. Robot. Autom. 2002, 14, 329–335. [Google Scholar] [CrossRef] [Scilit]
- Wang, T.; Du, W.; Zeng, L.; Su, L.; Zhao, Y.; Gu, F.; Liu, L.; Chi, Q. Design and testing of an end-effector for tomato picking. Agronomy 2023, 13, 947. [Google Scholar] [CrossRef] [Scilit]
- Ju, C.; Kim, J.; Seol, J.; Son, H.I. A review on multirobot systems in agriculture. Comput. Electron. Agric. 2022, 202, 107336. [Google Scholar] [CrossRef] [Scilit]
- Yu, L.; Yu, G.; Wang, H.; Sun, F.; Qian, M. Design and experiment of the end-effector with underactuated articulars for citrus picking. Trans. Chin. Soc. Agric. Eng. 2023, 39, 29–38. [Google Scholar]
- Zheng, Y.; Pi, J.; Guo, T.; Xu, L.; Liu, J.; Kong, J. Design and simulation of a gripper structure of cluster tomato based on manual picking behavior. Front. Plant Sci. 2022, 13, 974456. [Google Scholar] [CrossRef] [Scilit]
- Kam, J.; Vargas, A.M.; Coltin, B. An underactuated rigid-soft hybrid gripper prototype for conforming free-flying manipulation. In Proceedings of the IEEE International Conference on Robotics and Automation, Atlanta, GA, USA, 19–23 May 2025. [Google Scholar]
- Lee, K.; Wang, Y.; Zheng, C. Twister hand: Underactuated robotic gripper inspired by origami twisted tower. IEEE Trans. Robot. 2020, 36, 488–500. [Google Scholar] [CrossRef] [Scilit]
- Su, C.; Wang, R.; Lu, T.; Wang, S. SAU-RFC hand: A novel self-adaptive underactuated robot hand with rigid-flexible coupling fingers. Robotica 2023, 41, 511–529. [Google Scholar] [CrossRef] [Scilit]
- Fu, H.; Yang, J.; Du, W.; Wang, W.; Liu, G.; Yang, Z. Determination of coefficient of restitution of fresh market apples caused by fruit-to-fruit collisions with a sliding method. Biosyst. Eng. 2022, 224, 183–196. [Google Scholar] [CrossRef] [Scilit]
- Li, Z.; Liu, J.; Li, P. Relationship between Mechanical Properties and Mechanical Damage of Tomatoes in Robotic Harvesting. Trans. Chin. Soc. Agric. Eng. 2010, 26, 112–116. [Google Scholar]
- Fu, H.; He, L.; Ma, S.; Karkee, M.; Chen, D.; Zhang, Q.; Wang, S. ‘Jazz’ apple impact bruise responses to different cushioning materials. Trans. ASABE 2017, 60, 327–336. [Google Scholar] [CrossRef] [Scilit]
- Studman, C.; Brown, G.; Timm, E.; Schulte, N.; Vreede, M. Bruising on blush and non-blush sides in apple-to-apple impacts. Trans. ASAE 1997, 40, 1655–1663. [Google Scholar] [CrossRef] [Scilit]
- Liu, X.; Cao, Z.; Yang, L.; Chen, H.; Zhang, Y. Research on damage properties of apples based on static compression combined with the finite element method. Foods 2022, 11, 1851. [Google Scholar] [CrossRef] [Scilit]
- Birglen, L.; Gosselin, C.M. Kinetostatic analysis of underactuated fingers. IEEE Trans. Robot. Autom. 2004, 20, 211–221. [Google Scholar] [CrossRef] [Scilit]
- Huang, H.; Wang, R.; Huang, F.; Chen, J. Analysis and realization of a self-adaptive grasper grasping for non-destructive picking of fruits and vegetables. Comput. Electron. Agric. 2025, 232, 110119. [Google Scholar] [CrossRef] [Scilit]
- Meng, H.; Yang, K.; Zhou, L.; Shi, Y.; Cai, S.; Bao, G. Optimal design of linkage-driven underactuated hand for precise pinching and powerful grasping. IEEE Robot. Autom. Lett. 2024, 9, 3475–3482. [Google Scholar] [CrossRef] [Scilit]
- Zhu, J. Compression Damage and Quality Deterioration Mechanism of ‘Fuji’ Apple Fruit. Master’s Thesis, Anhui Agricultural University, Hefei, China, 2022. [Google Scholar]
- Bu, L.; Chen, C.; Hu, G.; Zhou, J.; Sugirbay, A.; Chen, J. Investigating the dynamic behavior of an apple branch-stem-fruit model using experimental and simulation analysis. Comput. Electron. Agric. 2021, 186, 106224. [Google Scholar] [CrossRef] [Scilit]
- Bu, L. Key Technologies of Robotic Apple Harvester in Constructed Orchard. Ph.D. Thesis, Northwest A&F University, Yangling, China, 2021. [Google Scholar]
- Bu, L.; Hu, G.; Chen, C.; Sugirbay, A.; Chen, J. Experimental and simulation analysis of optimum picking patterns for robotic apple harvesting. Sci. Hortic. 2020, 261, 108937. [Google Scholar] [CrossRef] [Scilit]
- Sun, J.; Sun, L.; Zhao, G.; Liu, J.; Chen, Z.; Jing, L.; Cao, X.; Zhang, H.; Tang, W.; Wang, J. Triboelectric force feedback-based fully actuated adaptive apple-picking gripper for optimized stability and non-destructive harvesting. Comput. Electron. Agric. 2025, 237, 110725. [Google Scholar] [CrossRef] [Scilit]
- Fu, H.; Du, W.; Yang, J.; Wang, W.; Wu, Z.; Yang, Z. Bruise measurement of fresh market apples caused by repeated impacts using a pendulum method. Postharvest Biol. Technol. 2023, 195, 112143. [Google Scholar] [CrossRef] [Scilit]
- Li, Y.; Du, X.; Wang, J.; Chai, L. Mechanical Properties of Apple Picking Damage. Agric. Eng. 2018, 8, 77–80. [Google Scholar]
- Wang, X.; Kang, H.; Zhou, H.; Au, W.; Wang, M.Y.; Chen, C. Development and evaluation of a robust soft robotic gripper for apple harvesting. Comput. Electron. Agric. 2023, 204, 107552. [Google Scholar] [CrossRef] [Scilit]
- Chen, K.; Li, T.; Yan, T.; Xie, F.; Feng, Q.; Zhu, Q.; Zhao, C. A soft gripper design for apple harvesting with force feedback and fruit slip detection. Agriculture 2022, 12, 1802. [Google Scholar] [CrossRef] [Scilit]
- Silwal, A.; Davidson, J.R.; Karkee, M.; Mo, C.; Zhang, Q.; Lewis, K. Design, integration, and field evaluation of a robotic apple harvester. J. Field Robot. 2017, 34, 1140–1159. [Google Scholar] [CrossRef] [Scilit]



| Serial Number | (mm) | (mm) | (mm) | (mm) | (N·mm/°) | Initial Torque (N·mm) | /×10−7 N) |
|---|---|---|---|---|---|---|---|
| 1 | 29.0 | 31.5 | 20.5 | 24.0 | 3.42 | 4.77 | 14.136 |
| 2 | 26.18 | 33.61 | 23.00 | 22.56 | 2.87 | 5.81 | 11.09 |
| 3 | 28.24 | 29.82 | 23.76 | 25.61 | 6.06 | 6.95 | 8.178 |
| 4 | 30.09 | 31.56 | 26.74 | 26.88 | 5.63 | 6.25 | 5.155 |
| 5 | 28.55 | 32.43 | 24.80 | 24.42 | 4.17 | 8.15 | 14.14 |
| 6 | 27.35 | 29.11 | 24.21 | 27.39 | 3.78 | 5.53 | 3.09 |
| 7 | 28.61 | 29.12 | 25.33 | 25.88 | 7.56 | 5.99 | 4.157 |
| 8 | 27.59 | 34.28 | 20.84 | 25.44 | 4.56 | 5.10 | 24.13 |
| 9 | 30.51 | 32.65 | 24.01 | 28.27 | 7.33 | 9.28 | 14.14 |
| 10 | 29.70 | 28.44 | 22.76 | 21.17 | 2.79 | 6.10 | 4.16 |
| Item | Category | Parameter Type | Value |
|---|---|---|---|
| Material parameters | Apple [36] | Poisson’s ratio | 0.33 |
| Elastic modulus (MPa) | 2.4 | ||
| Density (kg/m3) | 918.58 | ||
| Flexible silicone | Poisson’s ratio | 0.48 | |
| Elastic modulus (MPa) | 0.36 | ||
| Density (kg/m3) | 1300 | ||
| Model parameters | Torsional spring | Spring stiffness (N·mm/°) | 3.78 |
| Initial torsional moment (N·mm) | 5.53 | ||
| End-effector structure | Nylon density (material of end-effector) (kg/m3) | 670 | |
| Contact parameters between flexible silicone and apple | Contact stiffness (N/mm) | 10,000 | |
| Contact damping (N·s/mm) | 2.3 | ||
| Friction coefficients between flexible silicone and apple | Static friction coefficient | 0.7 | |
| Dynamic friction coefficient | 0.5 | ||
| Simulation control | Integration error | 1 × 10⁻⁴ | |
| Number of steps | 3000 |
| Contact Unit | Equivalent Stress | Diameter of the Apple | ||
|---|---|---|---|---|
| 70 mm | 80 mm | 90 mm | ||
| PPRS | SMX (MPa) | 3.81 × 10⁻² | 3.34 × 10⁻² | 2.14 × 10⁻² |
| SMN (MPa) | 2.89 × 10⁻⁴ | 2.56 × 10⁻⁴ | 1.44 × 10⁻⁴ | |
| MPRS | SMX (MPa) | 3.62 × 10⁻² | 2.53 × 10⁻² | 1.47 × 10⁻² |
| SMN (MPa) | 2.74 × 10⁻⁴ | 1.24 × 10⁻⁴ | 3.24 × 10⁻⁴ | |
| DPRS | SMX (MPa) | 5.21 × 10⁻² | 4.93 × 10⁻² | 4.49 × 10⁻² |
| SMN (MPa) | 8.11 × 10⁻⁴ | 6.27 × 10⁻⁴ | 1.25 × 10⁻⁴ | |
| Apple Size | PPRS Contact Force | MPRS Contact Force | Grasping Time | ||||||
|---|---|---|---|---|---|---|---|---|---|
| Simulation Results (N) | Experiment Results (Mean ± SD) | Relative Error (%) | Simulation Results (N) | Experiment Results (Mean ± SD) | Relative Error (%) | Simulation Results (s) | Experiment Results (Mean ± SD) | Relative Error (%) | |
| Small | 22.25 | 21.84 ± 0.68 | 1.88 | 21.37 | 20.08 ± 0.93 | 6.42 | 1.49 | 1.40 ± 0.03 | 6.43 |
| Medium | 21.39 | 19.44 ± 1.28 | 10.03 | 18.44 | 18.25 ± 0.96 | 1.04 | 1.32 | 1.29 ± 0.04 | 2.33 |
| Large | 21.03 | 19.65 ± 2.11 | 7.02 | 18.03 | 16.47 ± 1.10 | 9.47 | 1.12 | 1.21 ± 0.04 | 7.44 |
| End-Effector | Grasping Mean Time (s) | Precise Contact Force Control | Fruit Damage |
|---|---|---|---|
| Pneumatic Gripper [43] | 2.08 s | No | 4.55% |
| Soft Gripper [44] | Not specified | Yes | No visible damage |
| Passively compliant end-effector [45] | 1.50 s | No | No visible damage |
| Underactuated Rigid–Flexible Coupled End-Effector (our team) | 1.30 s | Yes | No visible damage |
Disclaimer/Publisher’s Note: The statements, opinions and data contained in all publications are solely those of the individual author(s) and contributor(s) and not of MDPI and/or the editor(s). MDPI and/or the editor(s) disclaim responsibility for any injury to people or property resulting from any ideas, methods, instructions or products referred to in the content. |
© 2026 by the authors. Licensee MDPI, Basel, Switzerland. This article is an open access article distributed under the terms and conditions of the Creative Commons Attribution (CC BY) license.
Share and Cite
Li, Z.; Zhang, Z.; Li, J.; Hou, G.; Wang, X.; Li, Y.; Ding, H.; Li, Y. Design and Evaluation of an Underactuated Rigid–Flexible Coupled End-Effector for Non-Destructive Apple Harvesting. Agriculture 2026, 16, 178. https://doi.org/10.3390/agriculture16020178
Li Z, Zhang Z, Li J, Hou G, Wang X, Li Y, Ding H, Li Y. Design and Evaluation of an Underactuated Rigid–Flexible Coupled End-Effector for Non-Destructive Apple Harvesting. Agriculture. 2026; 16(2):178. https://doi.org/10.3390/agriculture16020178
Chicago/Turabian StyleLi, Zeyi, Zhiyuan Zhang, Jingbin Li, Gang Hou, Xianfei Wang, Yingjie Li, Huizhe Ding, and Yufeng Li. 2026. "Design and Evaluation of an Underactuated Rigid–Flexible Coupled End-Effector for Non-Destructive Apple Harvesting" Agriculture 16, no. 2: 178. https://doi.org/10.3390/agriculture16020178
APA StyleLi, Z., Zhang, Z., Li, J., Hou, G., Wang, X., Li, Y., Ding, H., & Li, Y. (2026). Design and Evaluation of an Underactuated Rigid–Flexible Coupled End-Effector for Non-Destructive Apple Harvesting. Agriculture, 16(2), 178. https://doi.org/10.3390/agriculture16020178