Article

Improved UNet-Based Shoreline Detection Method in Real Time for Unmanned Surface Vehicle

1
Merchant Marine College, Shanghai Maritime University, Shanghai 201306, China
2
Navigation College, Dalian Maritime University, Dalian 116026, China
*
Author to whom correspondence should be addressed.
J. Mar. Sci. Eng. 2023, 11(5), 1049; https://doi.org/10.3390/jmse11051049
Submission received: 24 March 2023 / Revised: 22 April 2023 / Accepted: 9 May 2023 / Published: 15 May 2023
(This article belongs to the Special Issue Application of Artificial Intelligence in Maritime Transportation)

Abstract

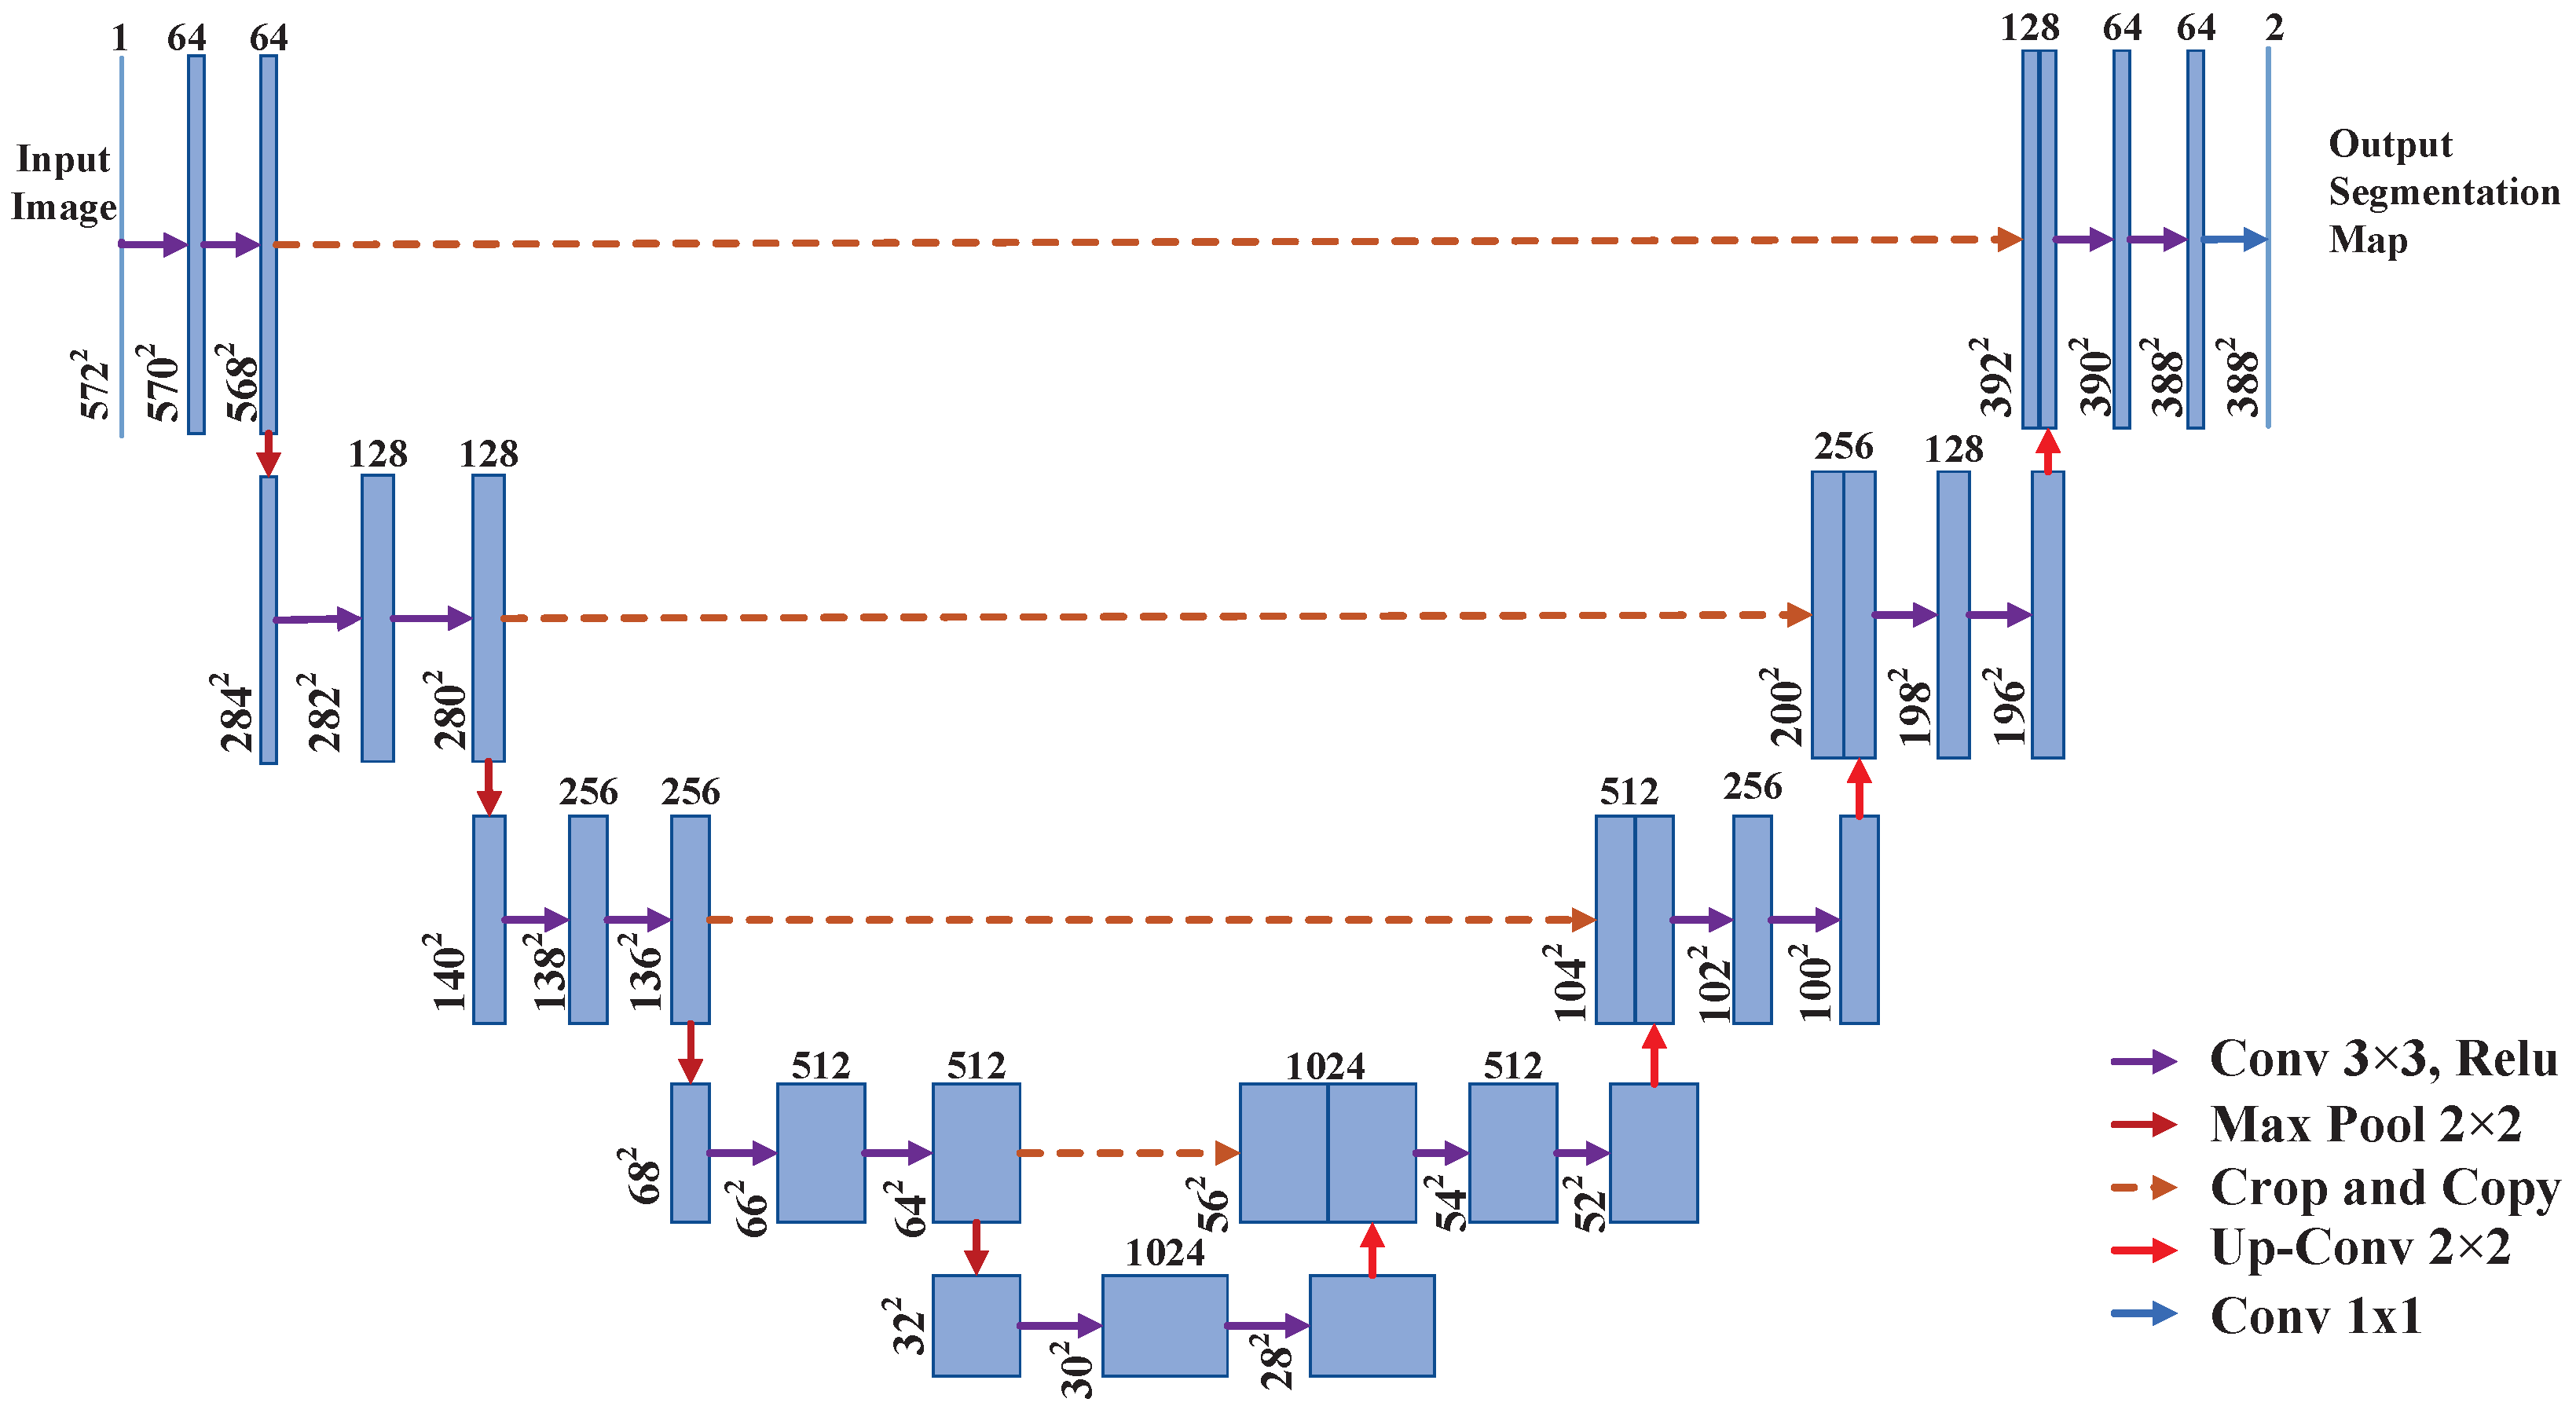
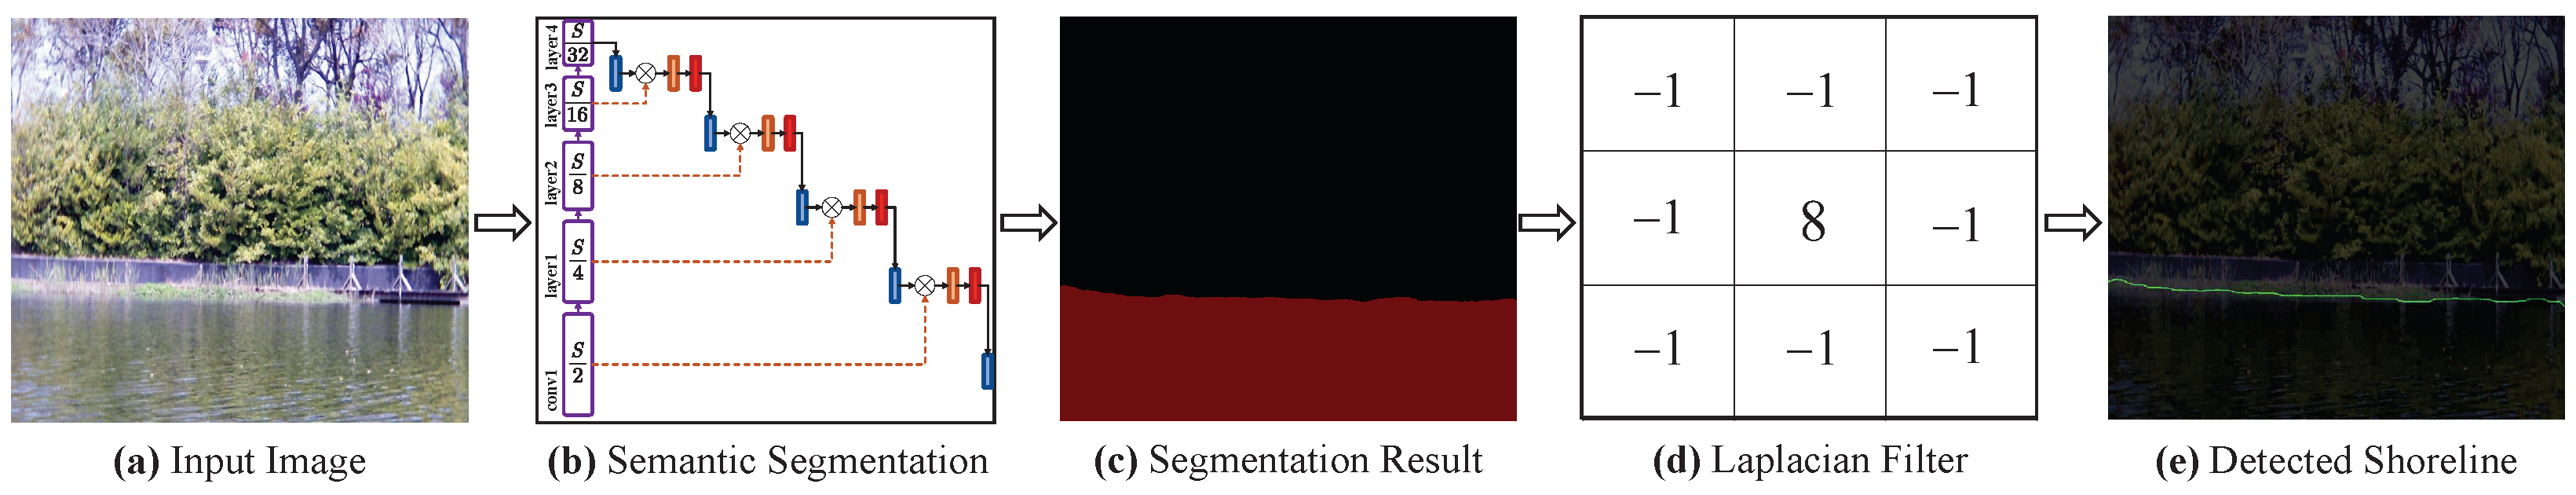
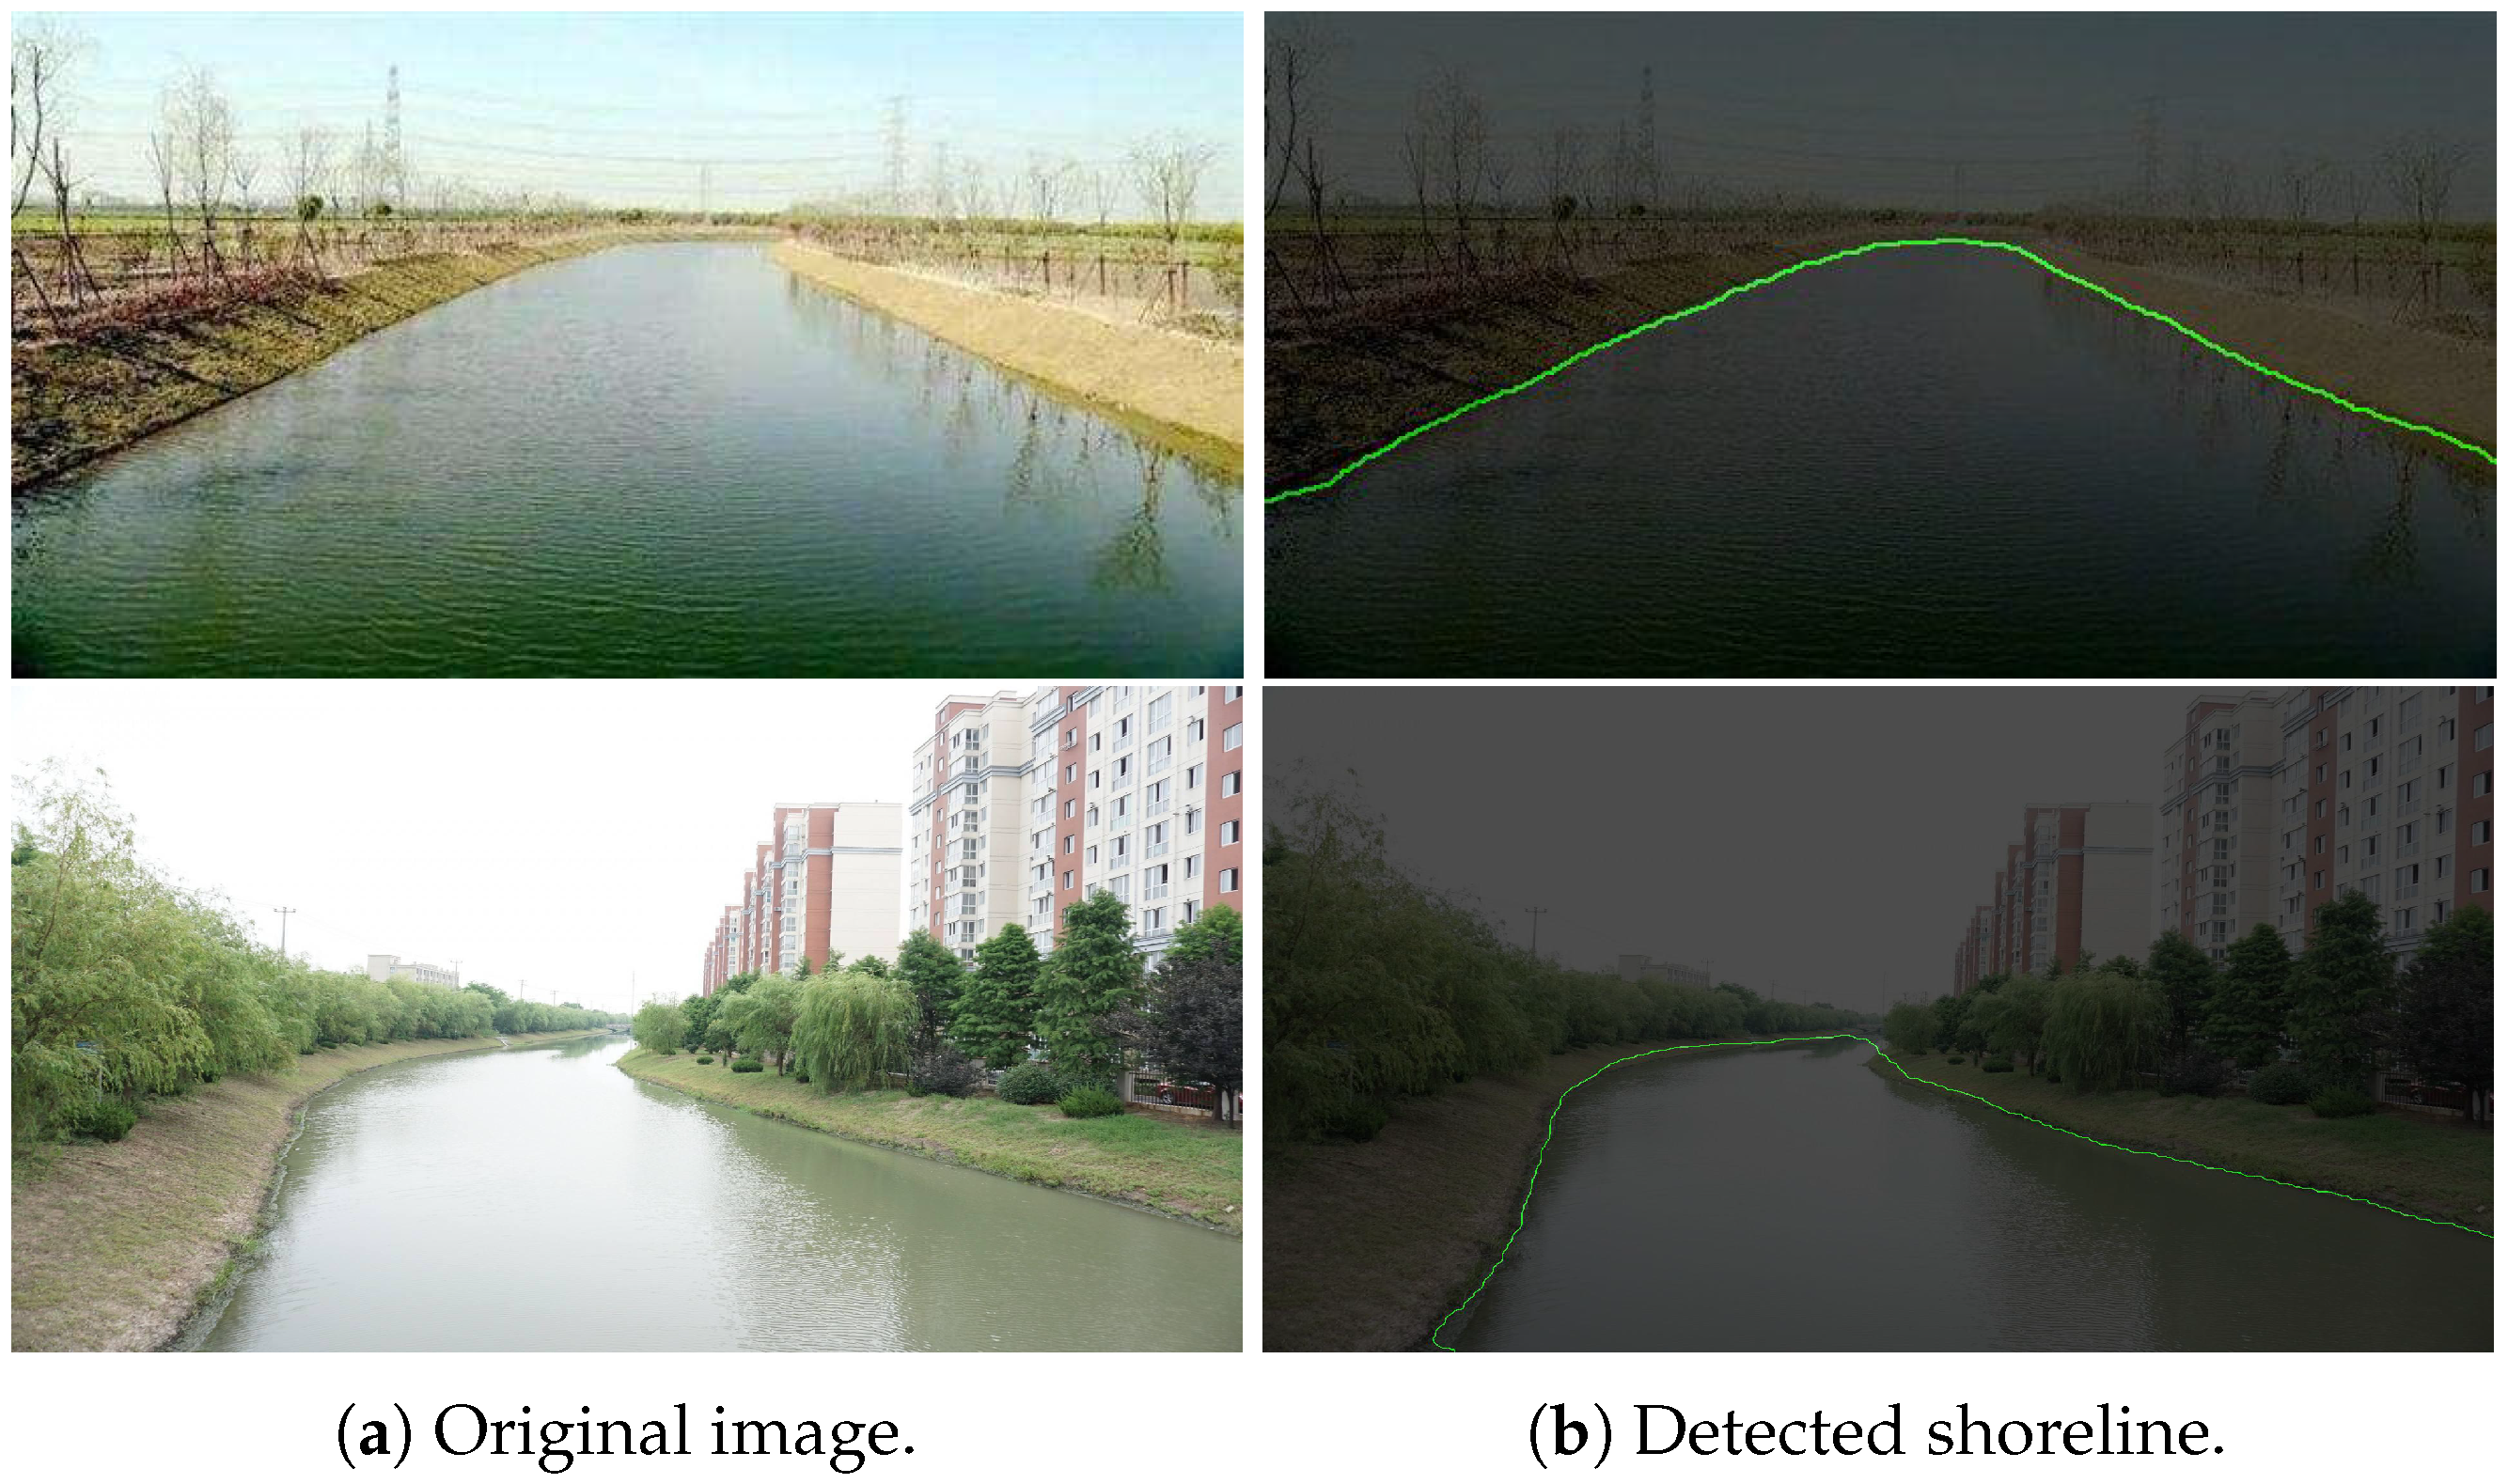
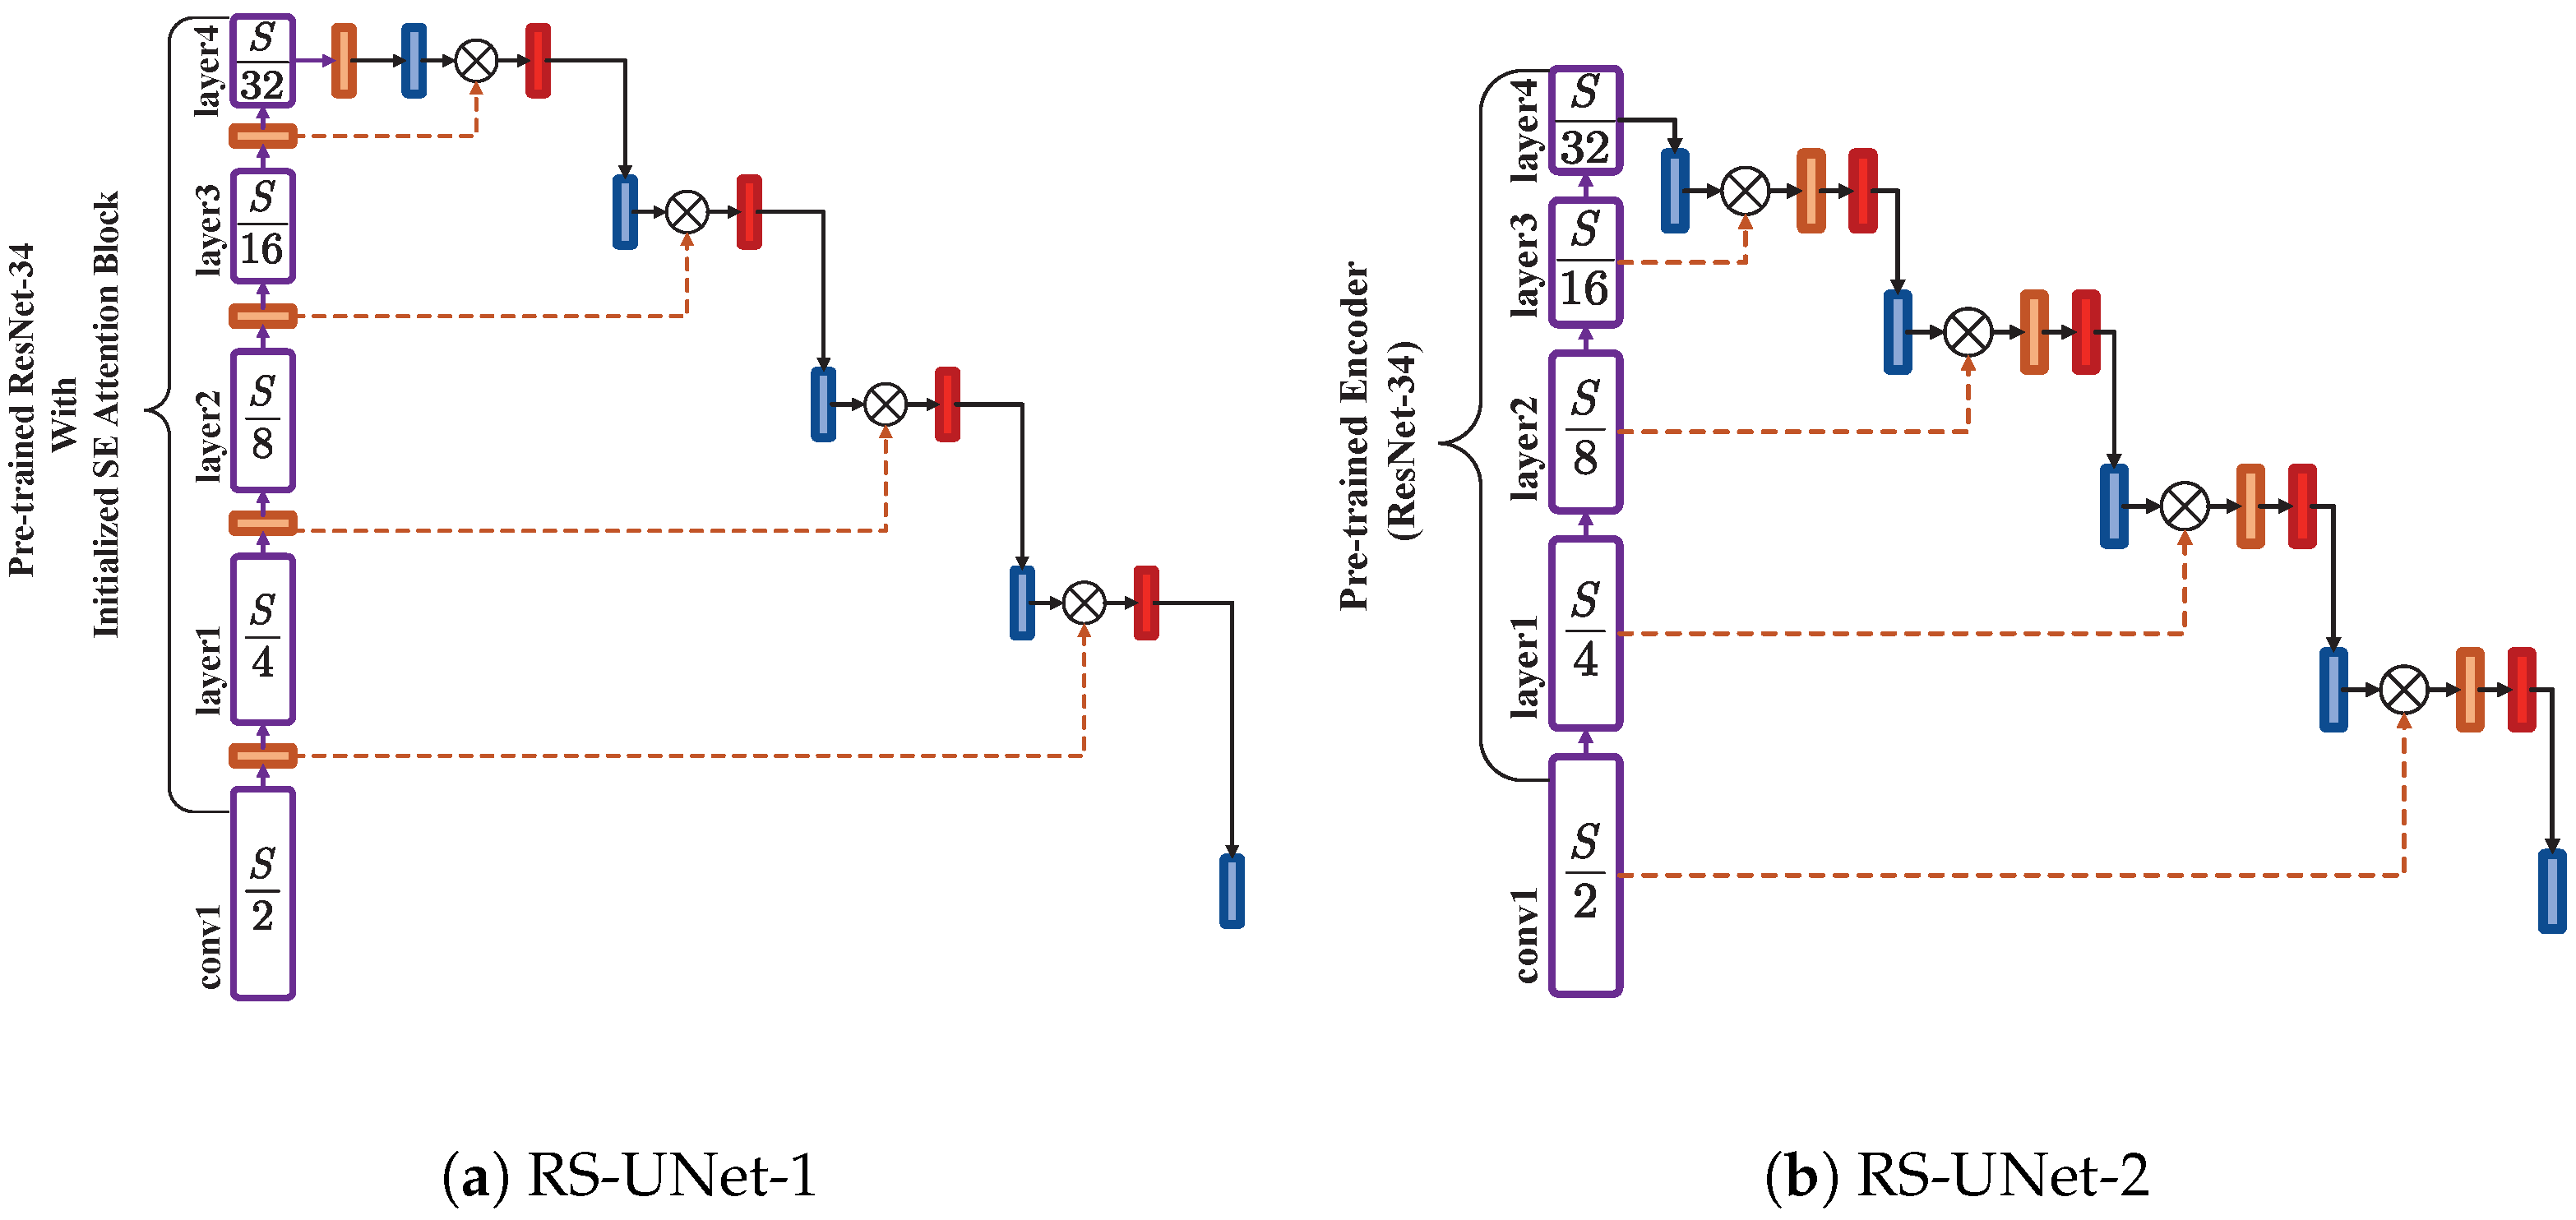
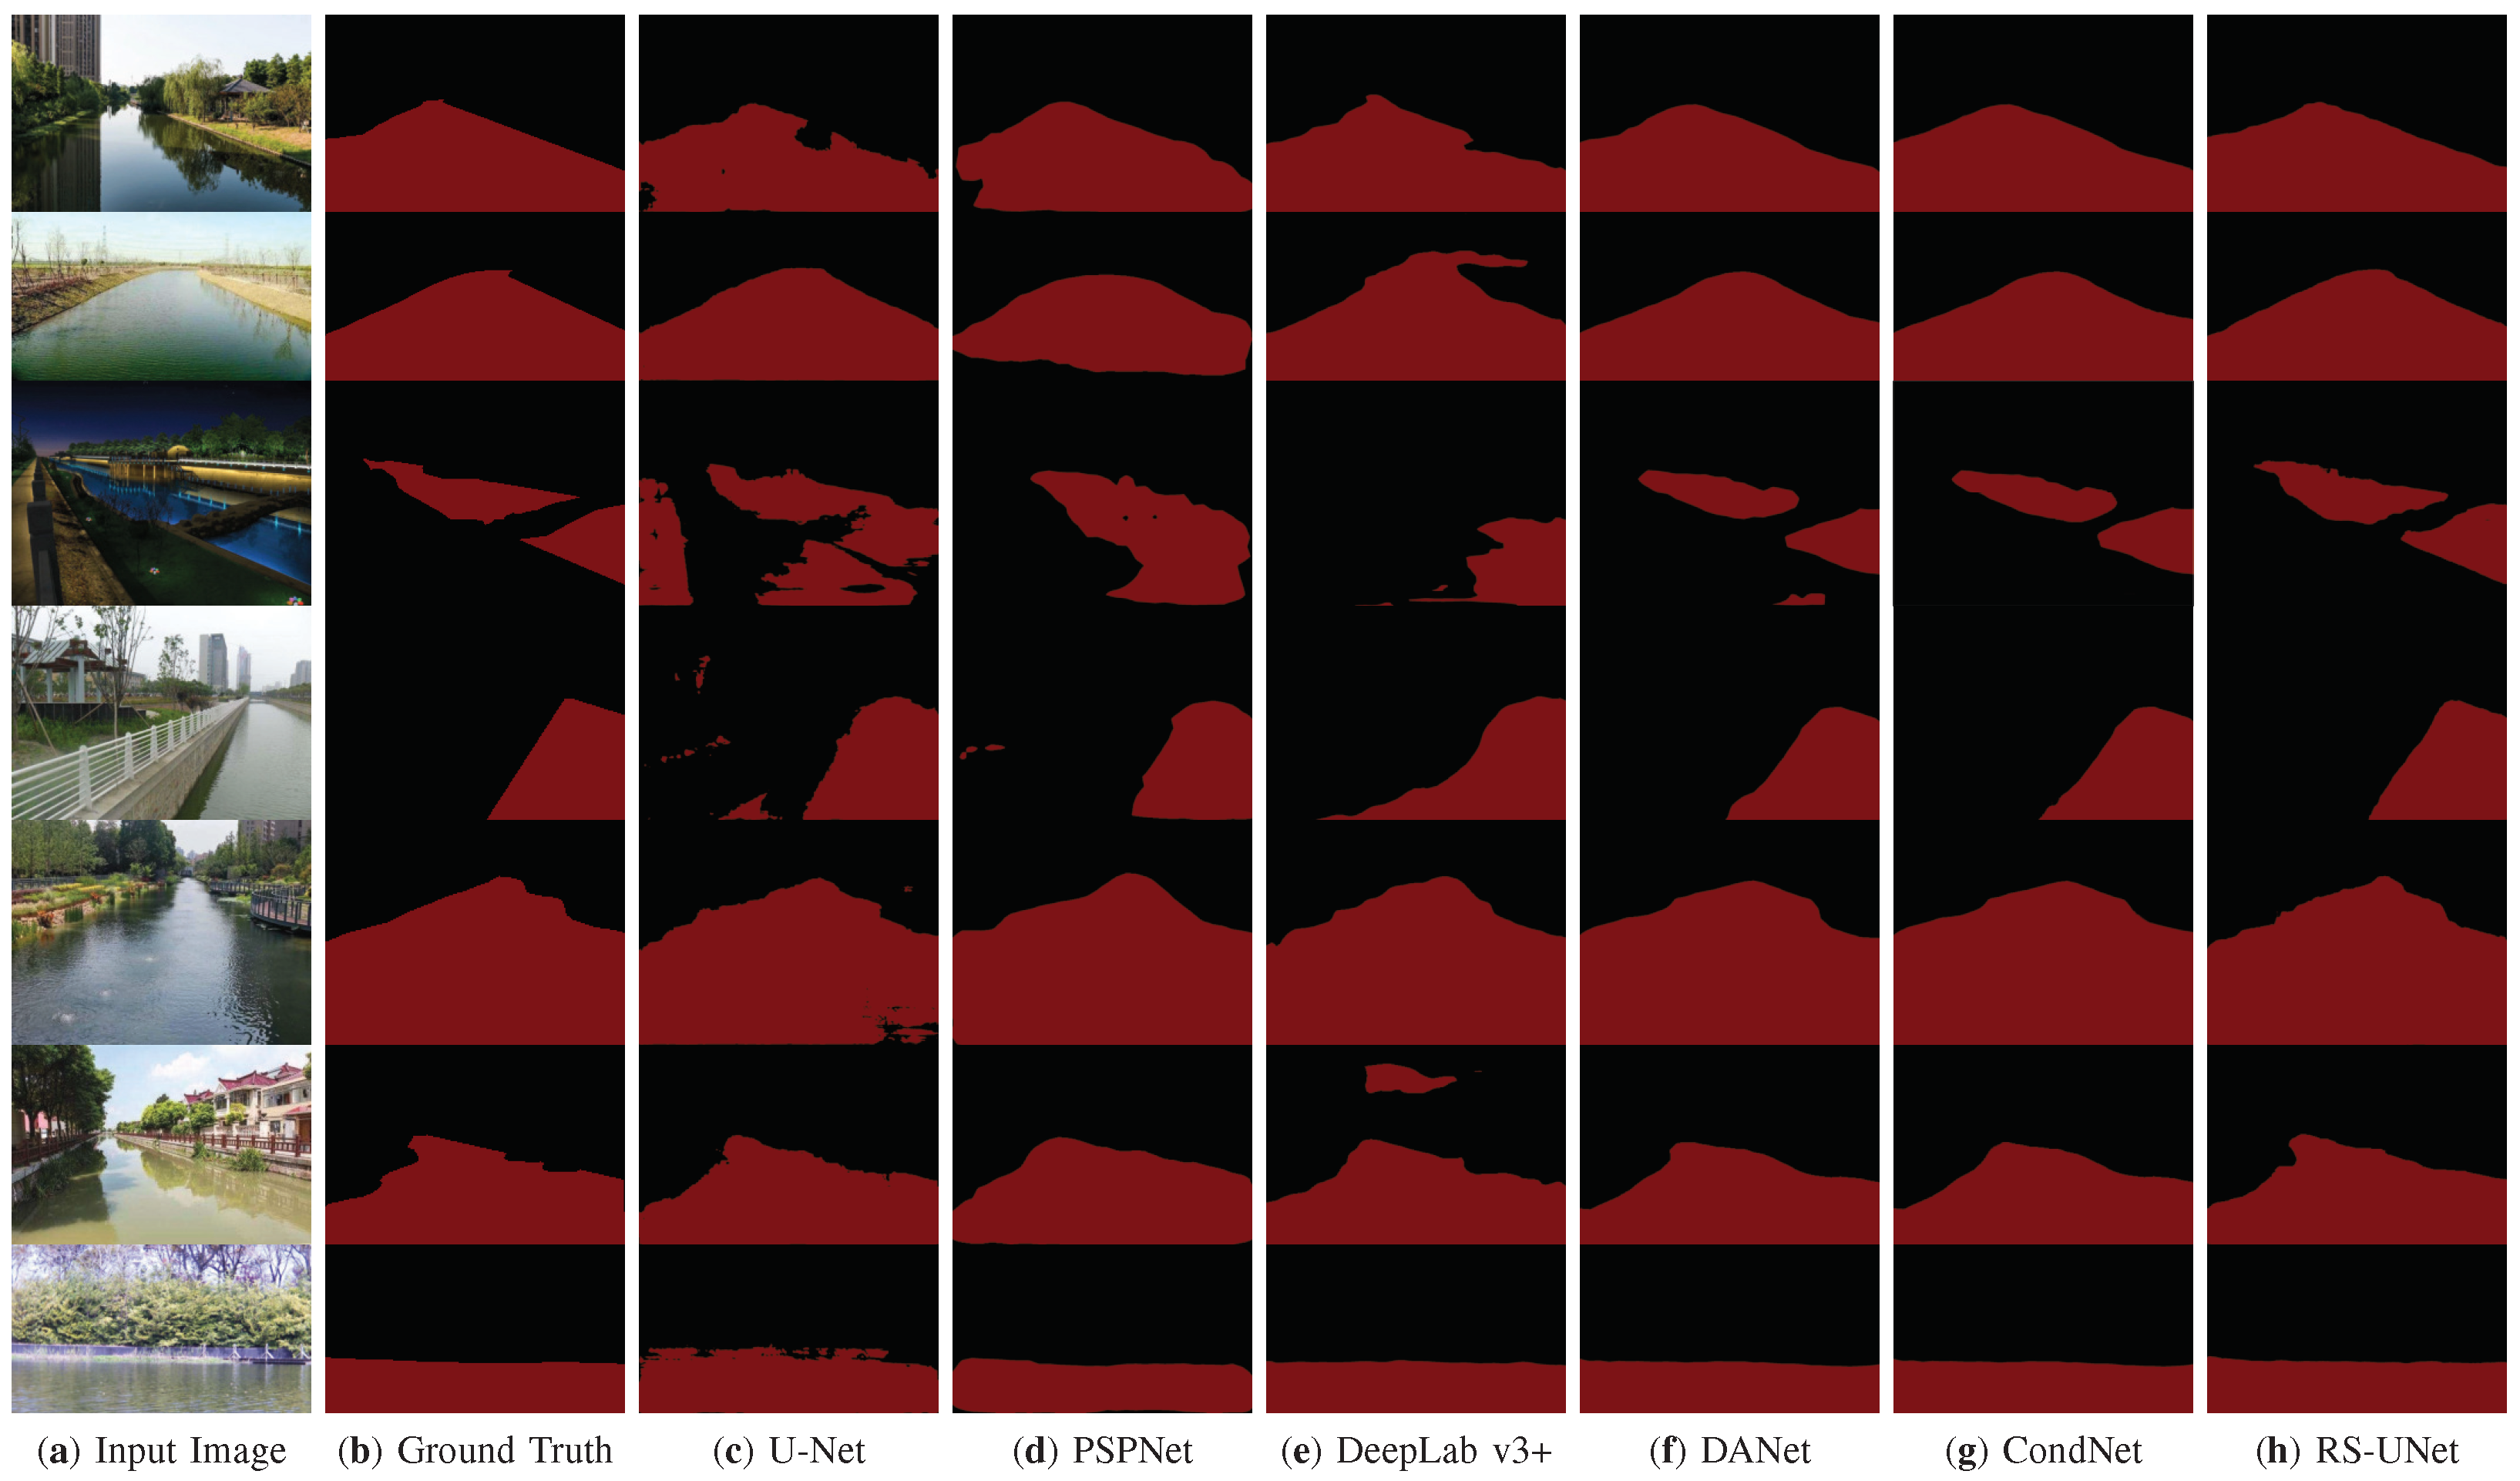
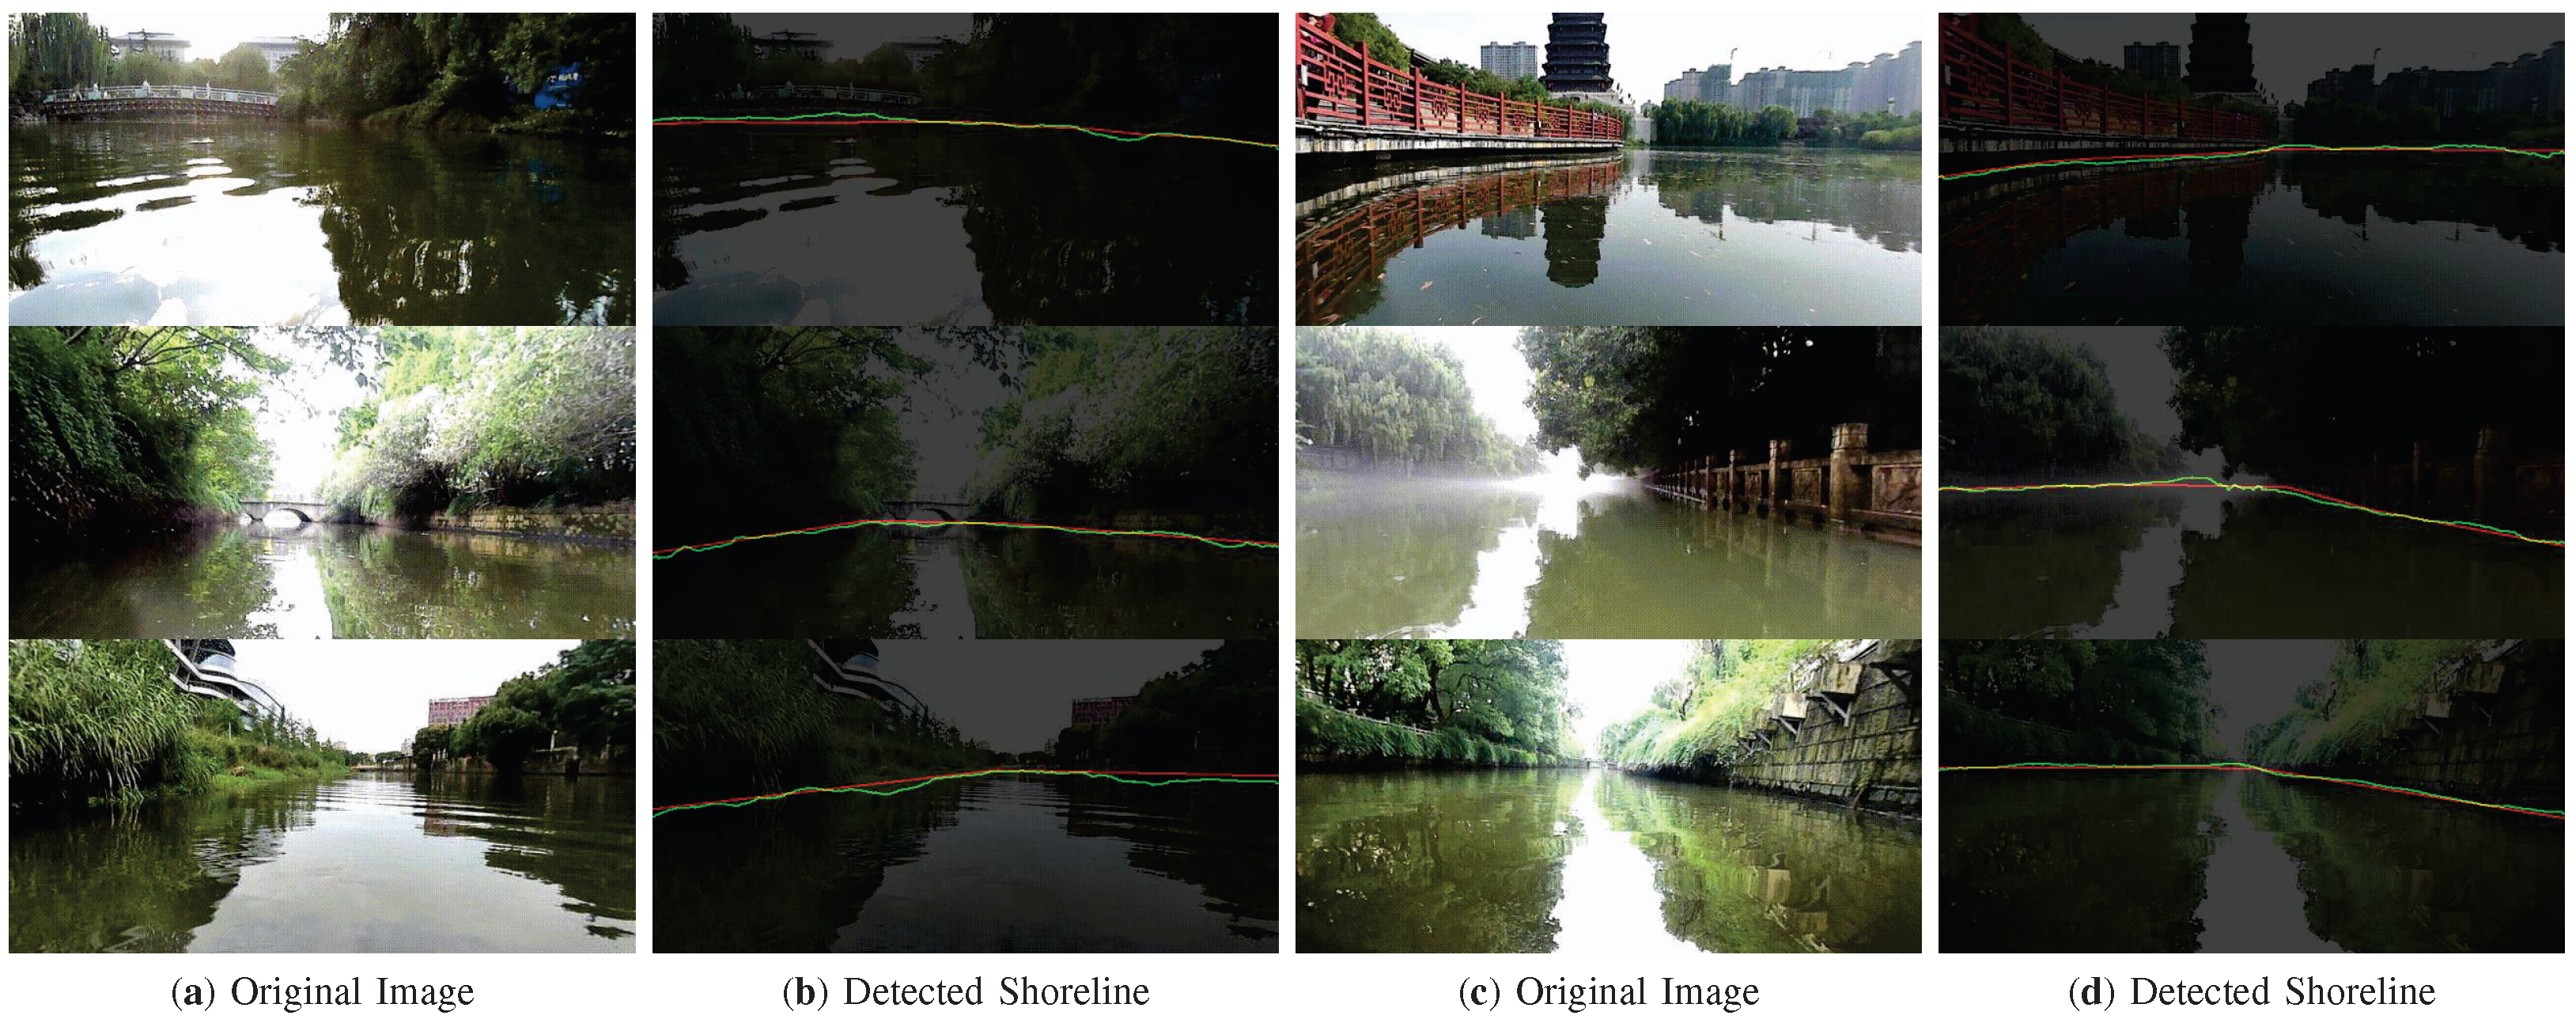
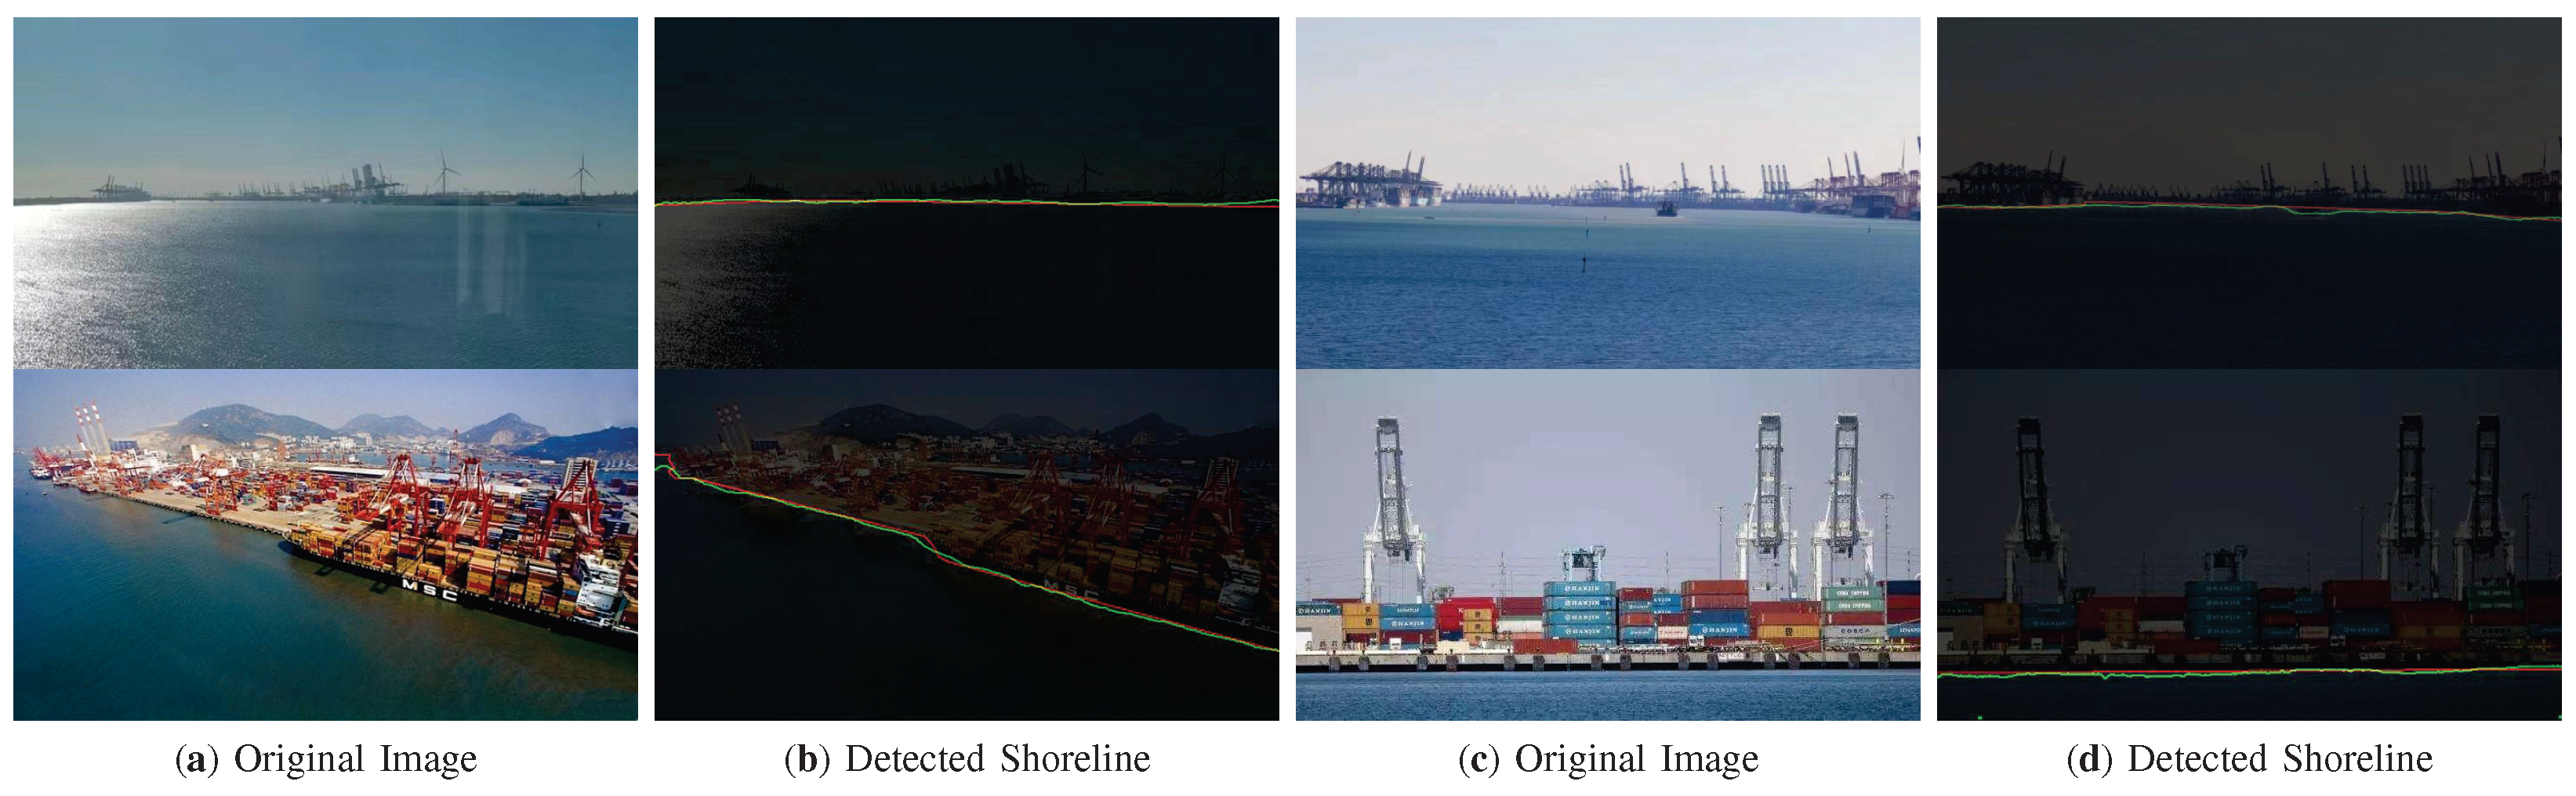
Accurate and real-time monitoring of the shoreline through cameras is an invaluable guarantee for the safety of near-shore navigation and berthing of unmanned surface vehicles; existing shoreline detection methods cannot meet both these requirements. Therefore, we propose an improved shoreline detection method to detect shorelines accurately and in real time. We define shoreline detection as the combination of water surface area segmentation and edge detection, the key to which is segmentation. To detect shorelines accurately and in real time, we propose an improved U-Net for water segmentation. This network is based on U-Net, using ResNet-34 as the backbone to enhance the feature extraction capability, with a concise decoder integrated attention mechanism to improve the processing speed while ensuring the accuracy of water surface segmentation. We also introduce transfer learning to improve training efficiency and solve the problem of insufficient data. When obtaining the segmentation result, the Laplace edge detection algorithm is applied to detect the shoreline. Experiments show that our network achieves 97.05% MIoU and 40 FPS with the fewest parameters, which is better than mainstream segmentation networks, and also demonstrate that our shoreline detection method can effectively detect shorelines in real time in various environments.
Keywords: water surface segmentation; attention mechanism; edge detection; shoreline detection water surface segmentation; attention mechanism; edge detection; shoreline detection