
Vision-Based Headland Boundary Perception and Decision-Making for Turn Initiation of Agricultural Machinery



Abstract
1. Introduction
2. Materials and Methods
2.1. System Overview
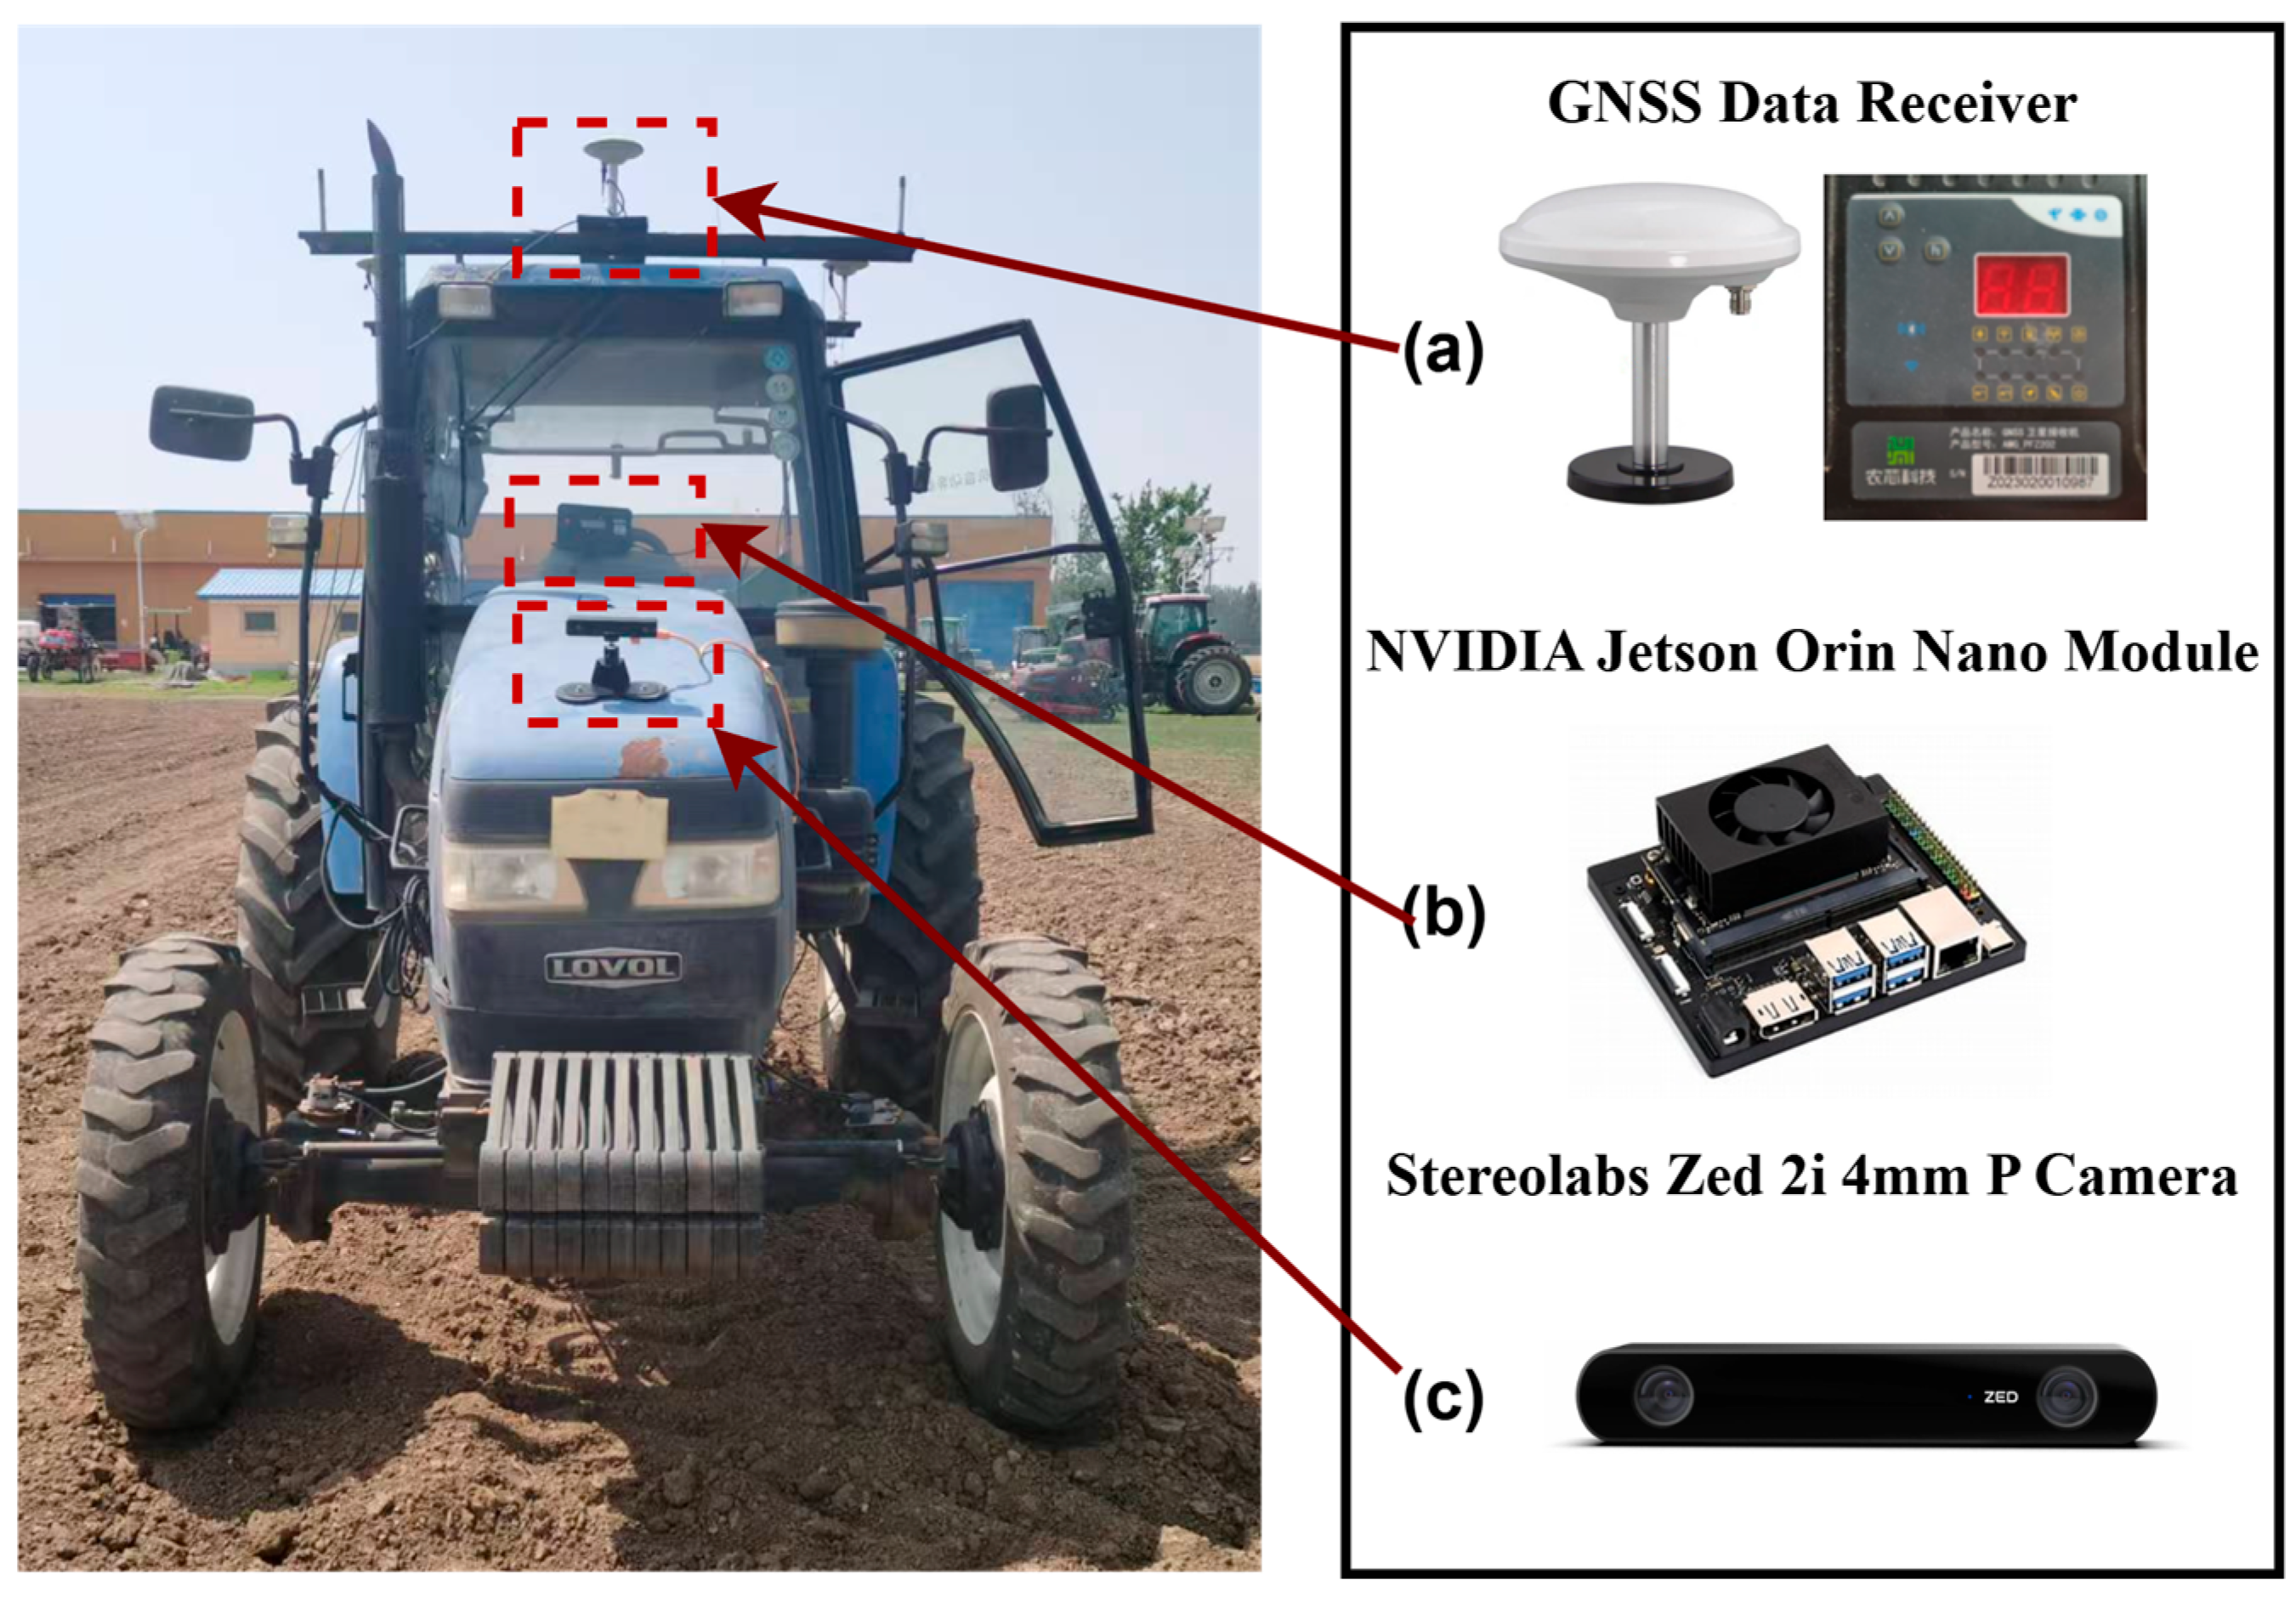
2.1.1. Hardware Configuration
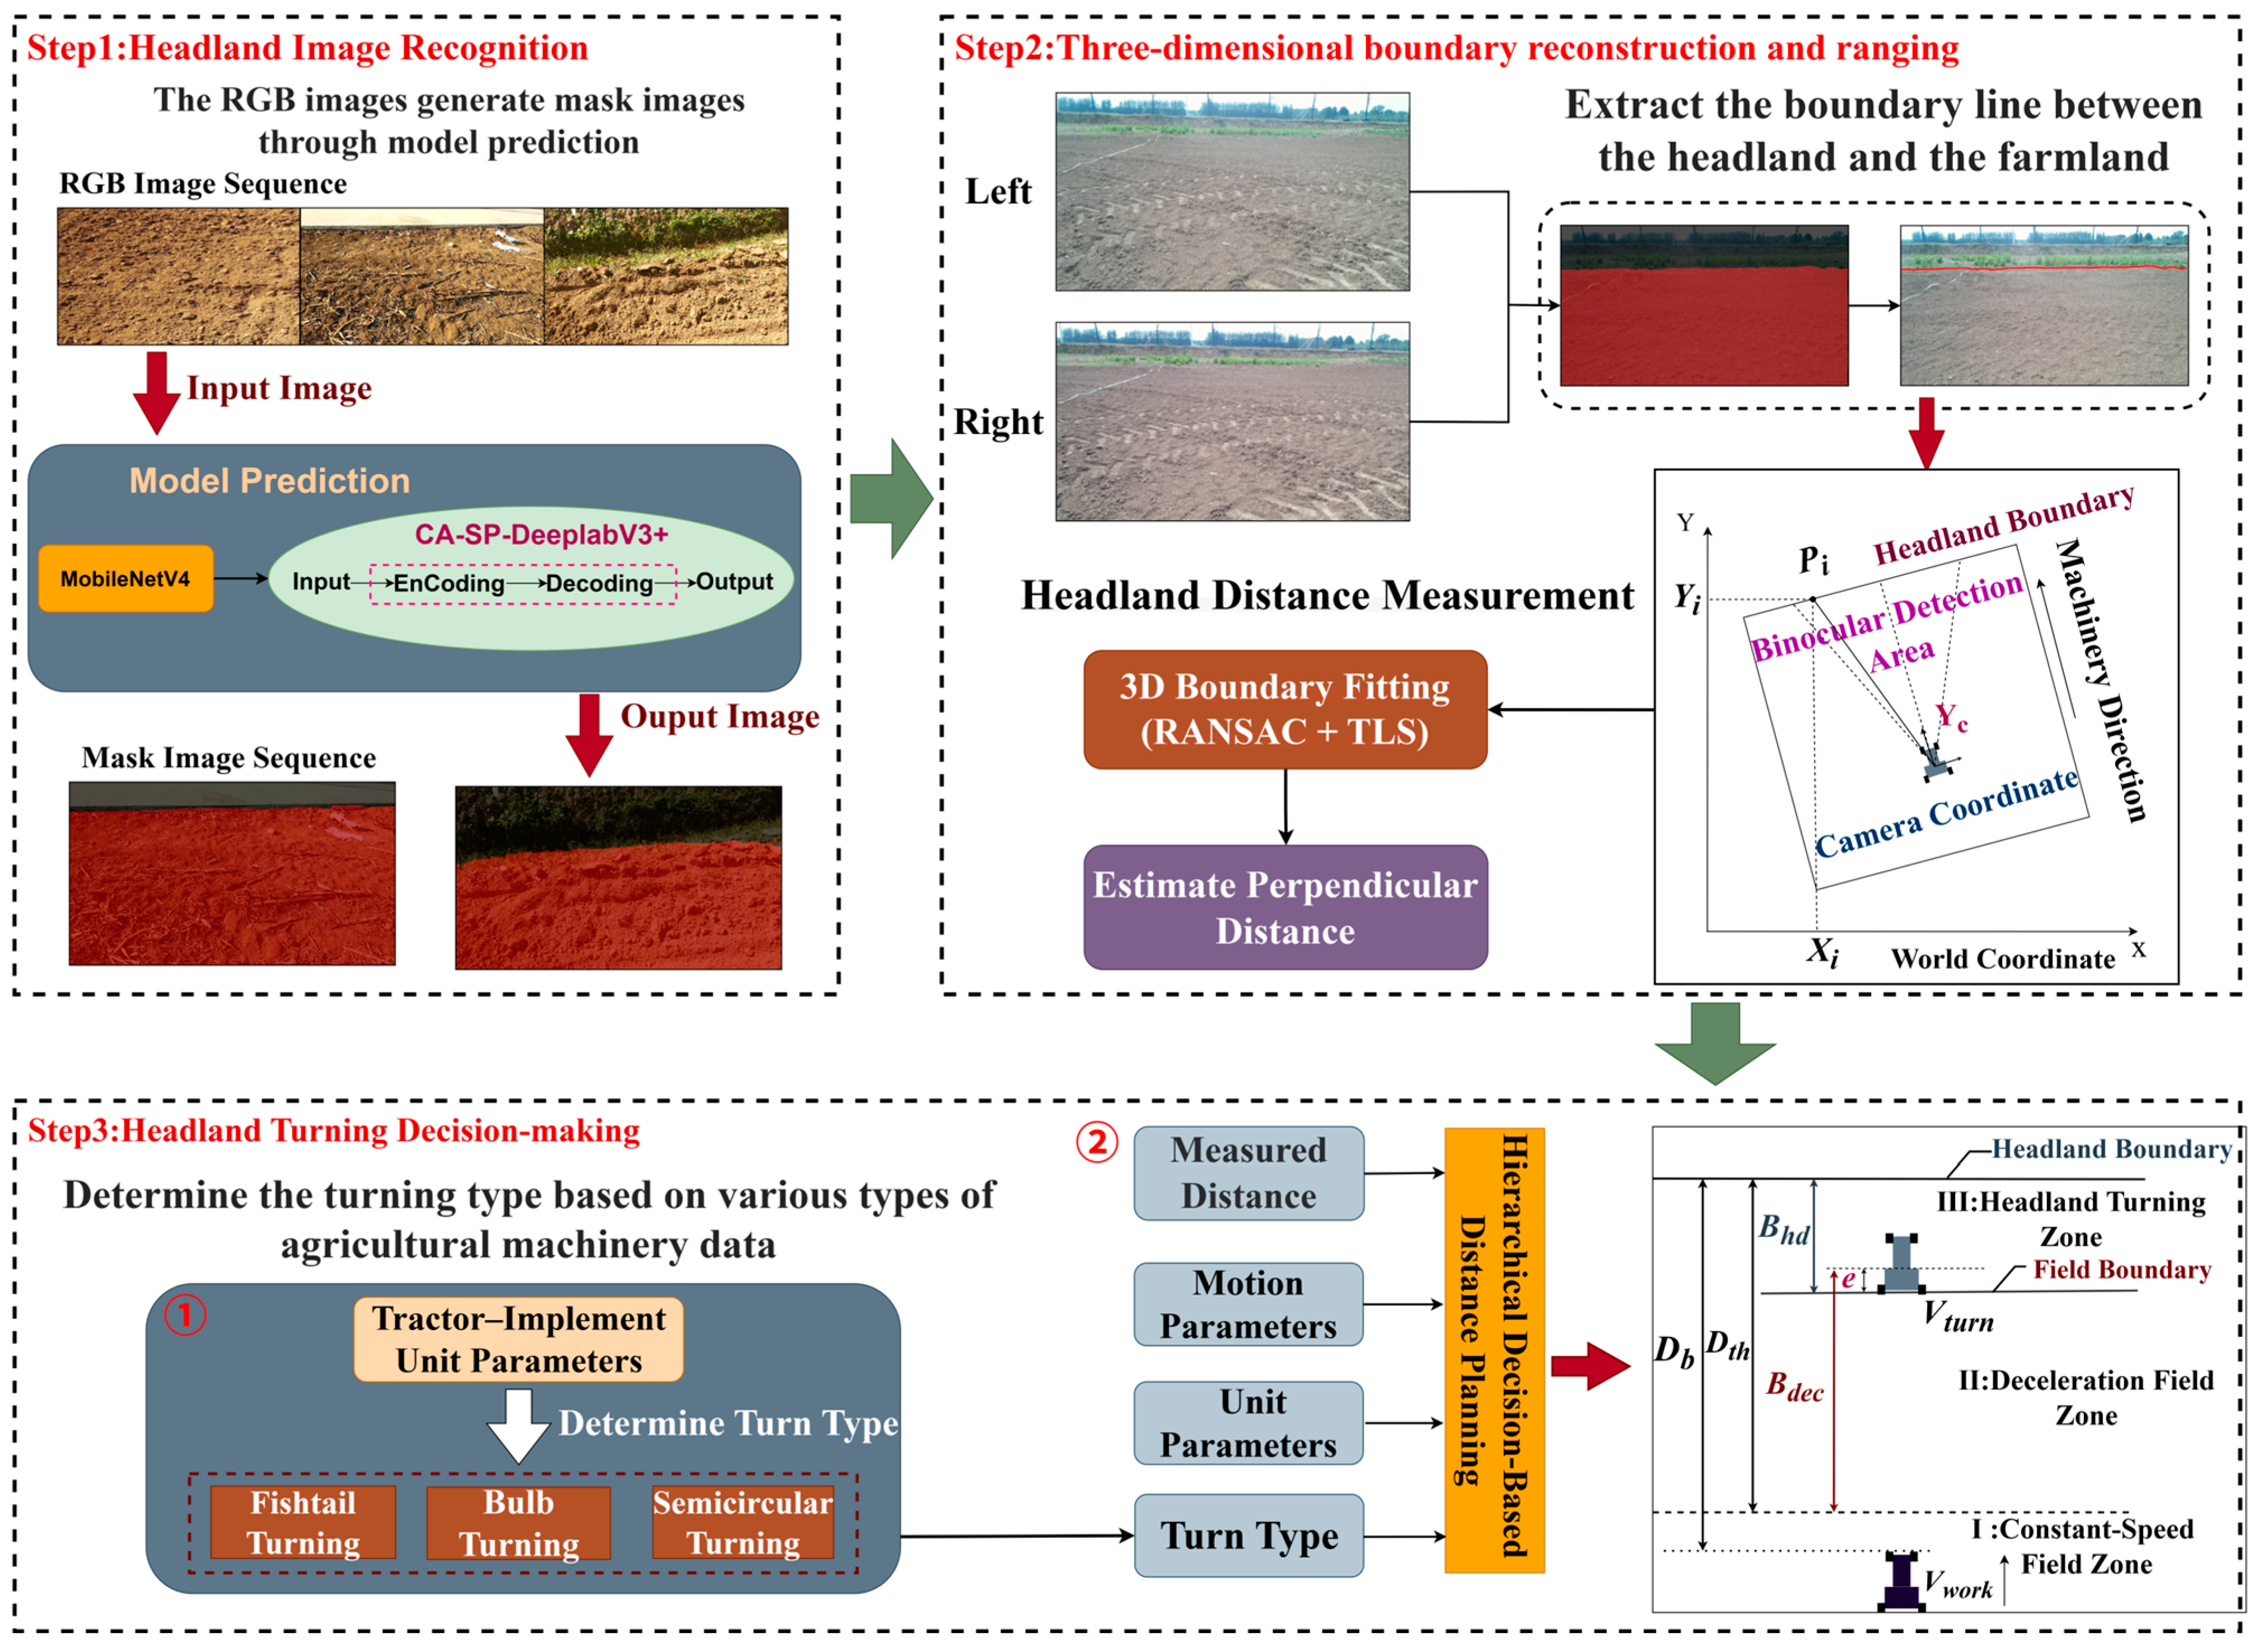
2.1.2. System Workflow
2.2. Headland Image Recognition
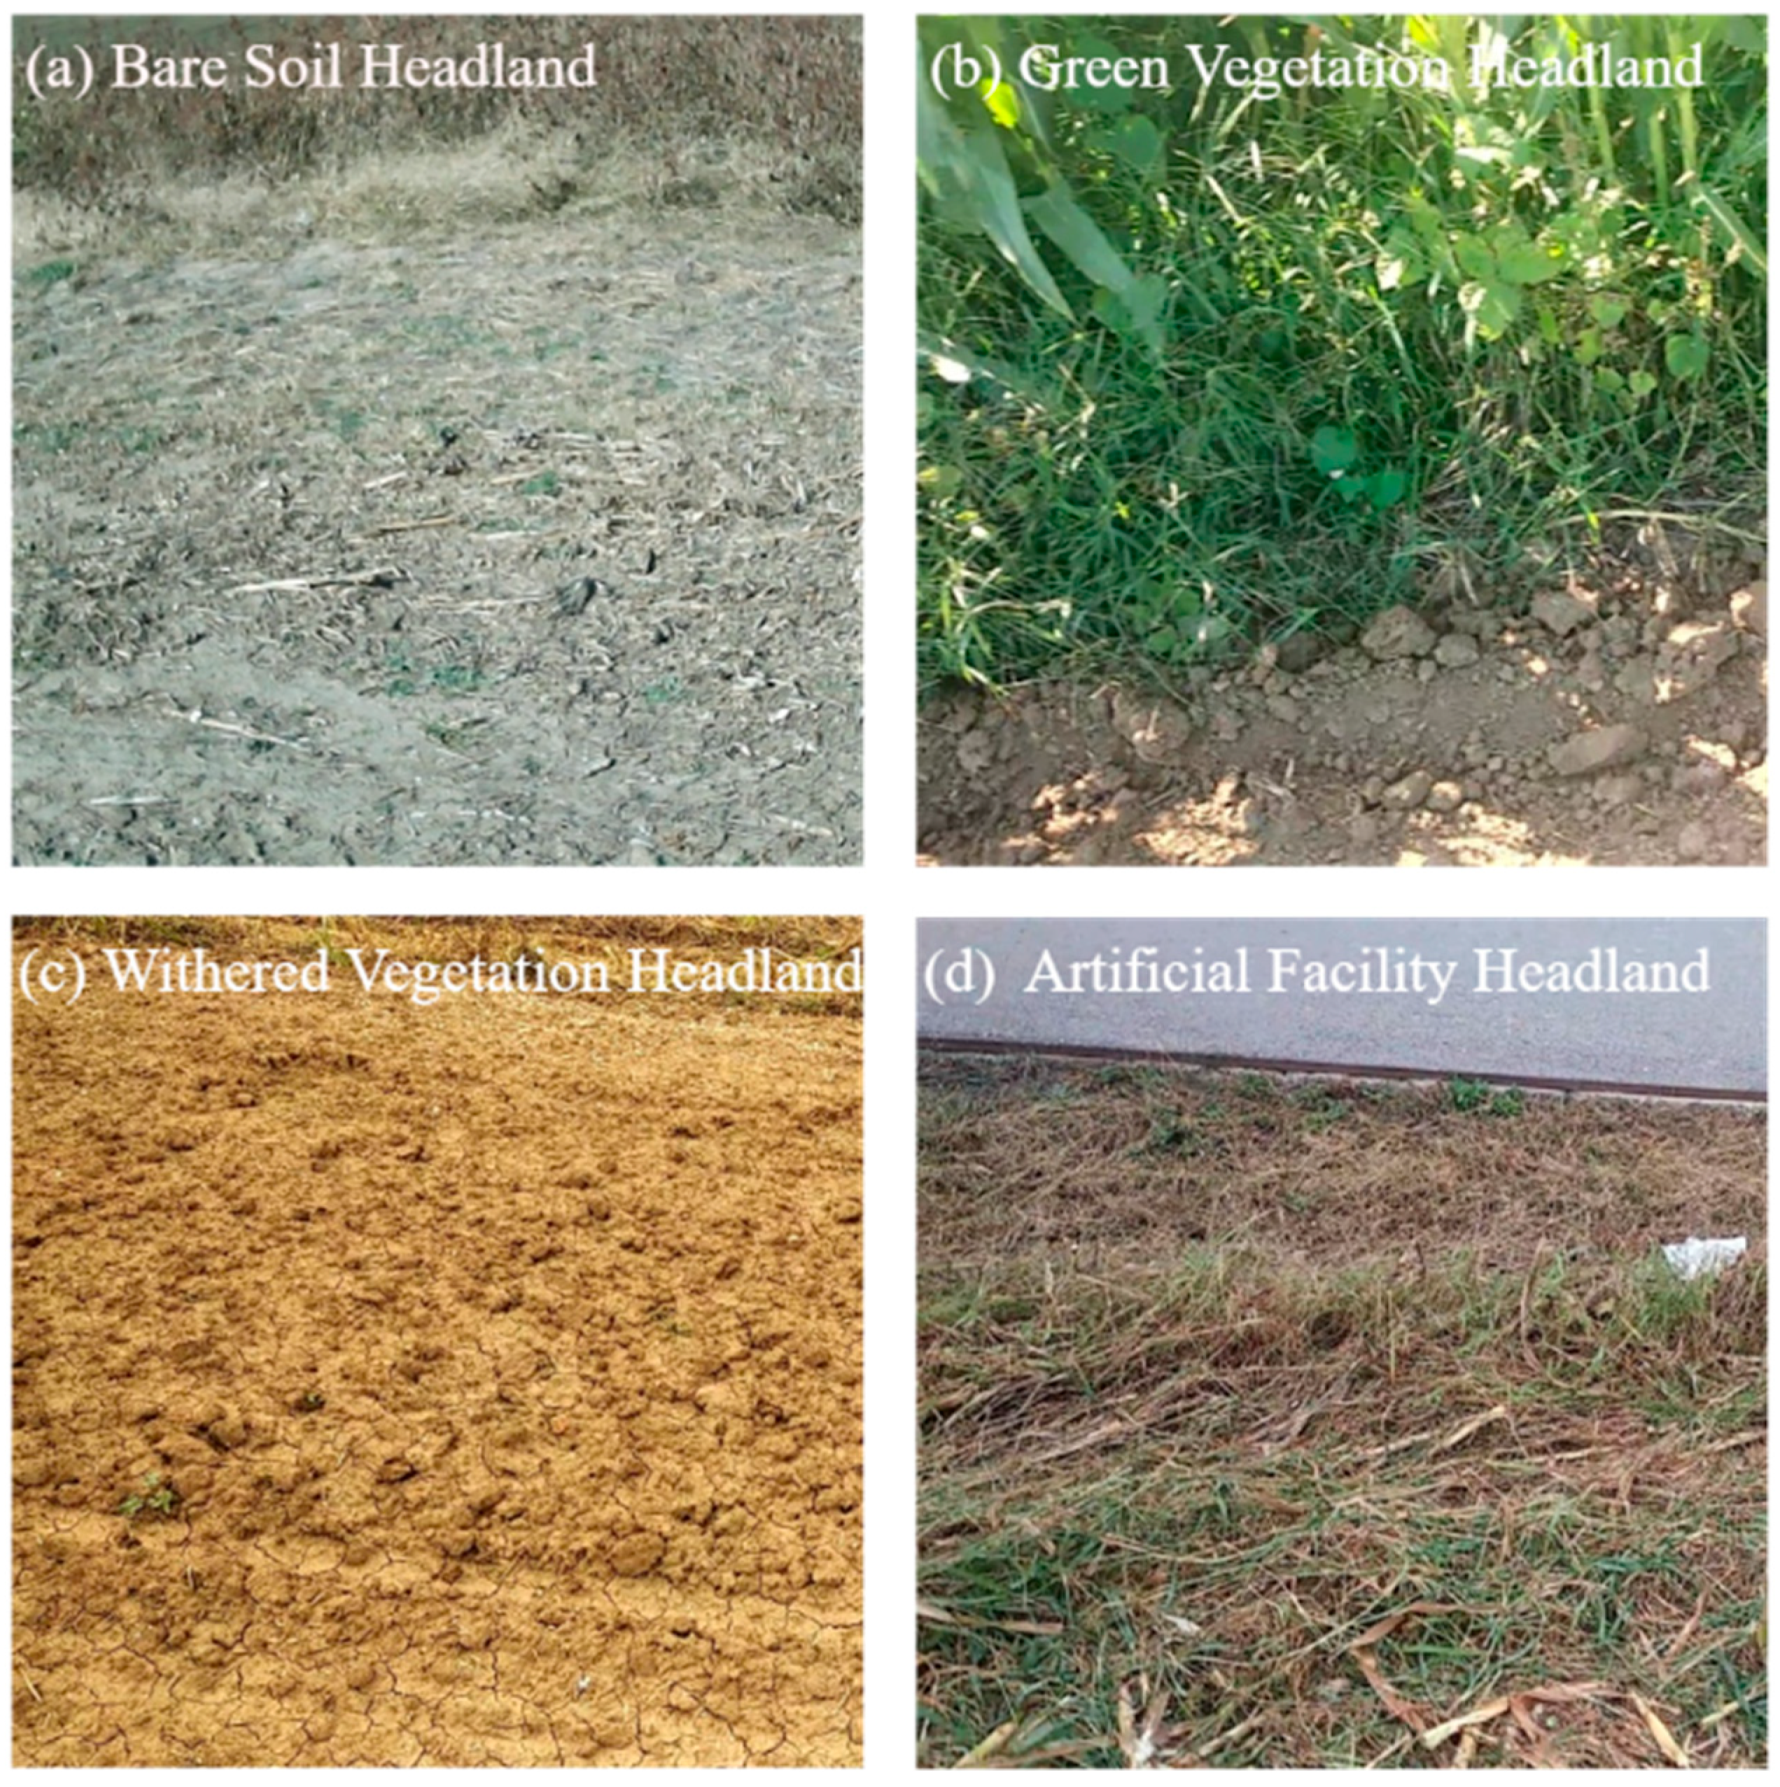
2.2.1. Dataset Construction
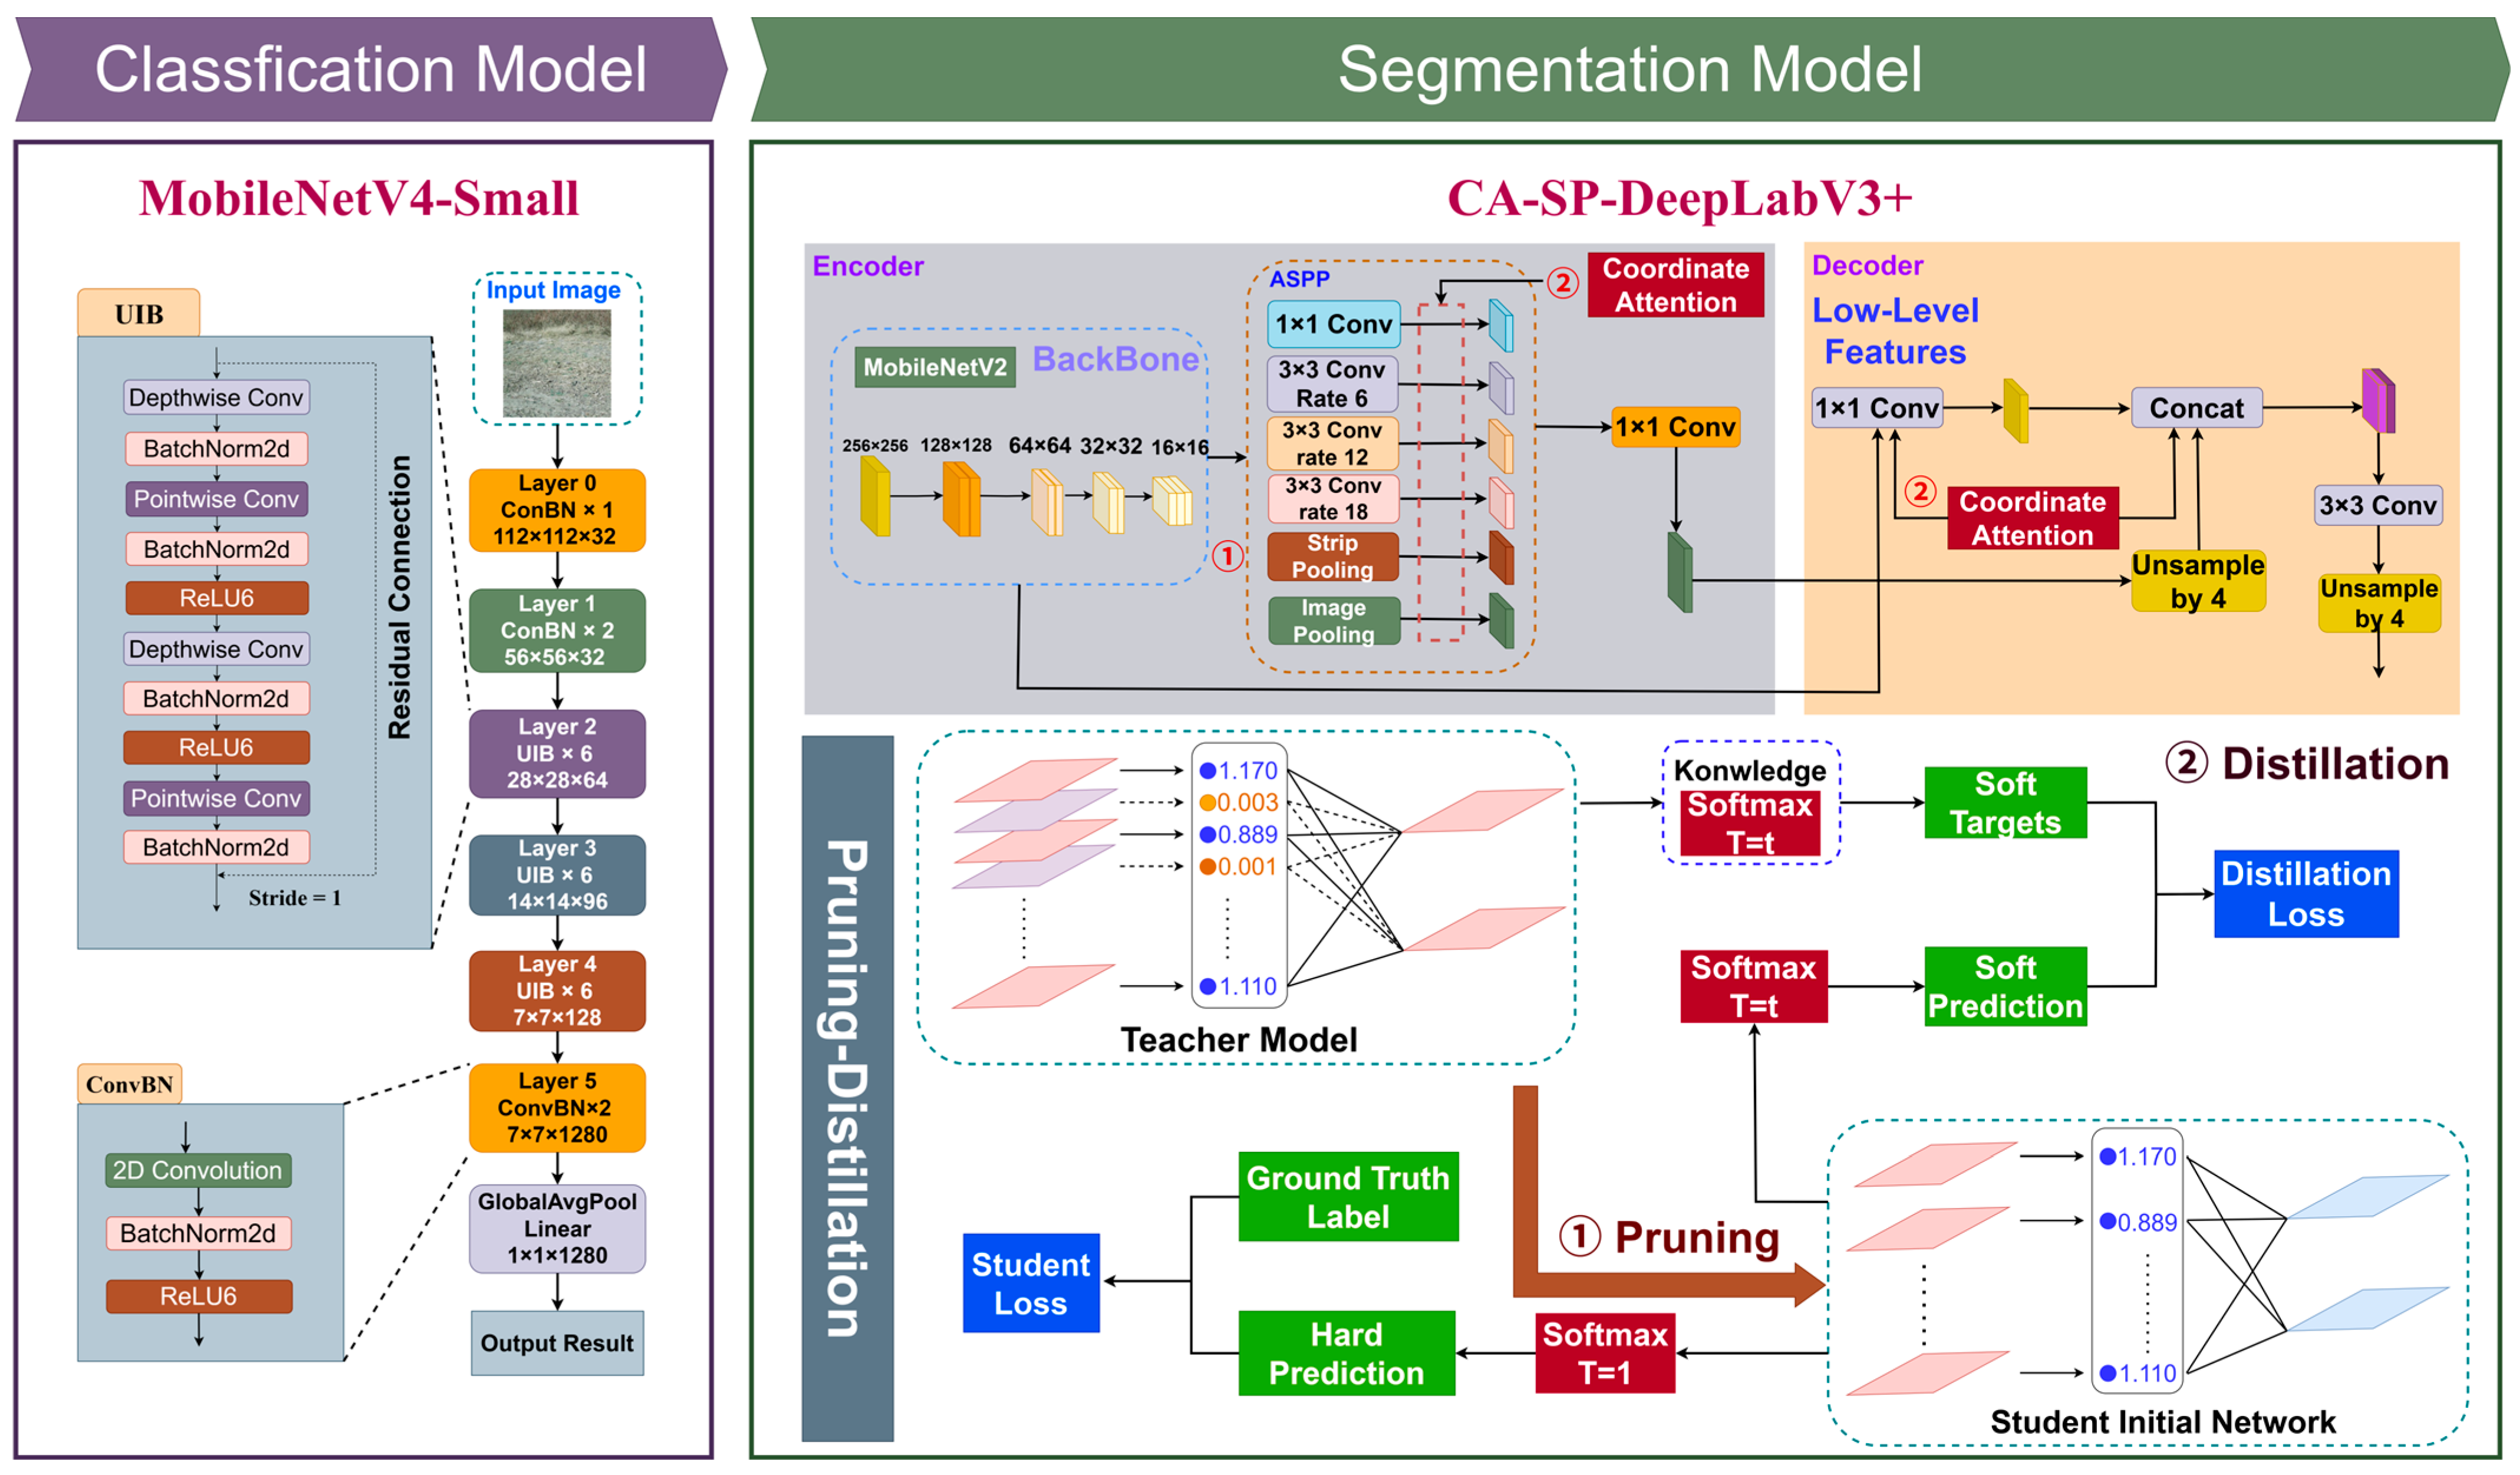
2.2.2. Two-Stage Headland Recognition Method
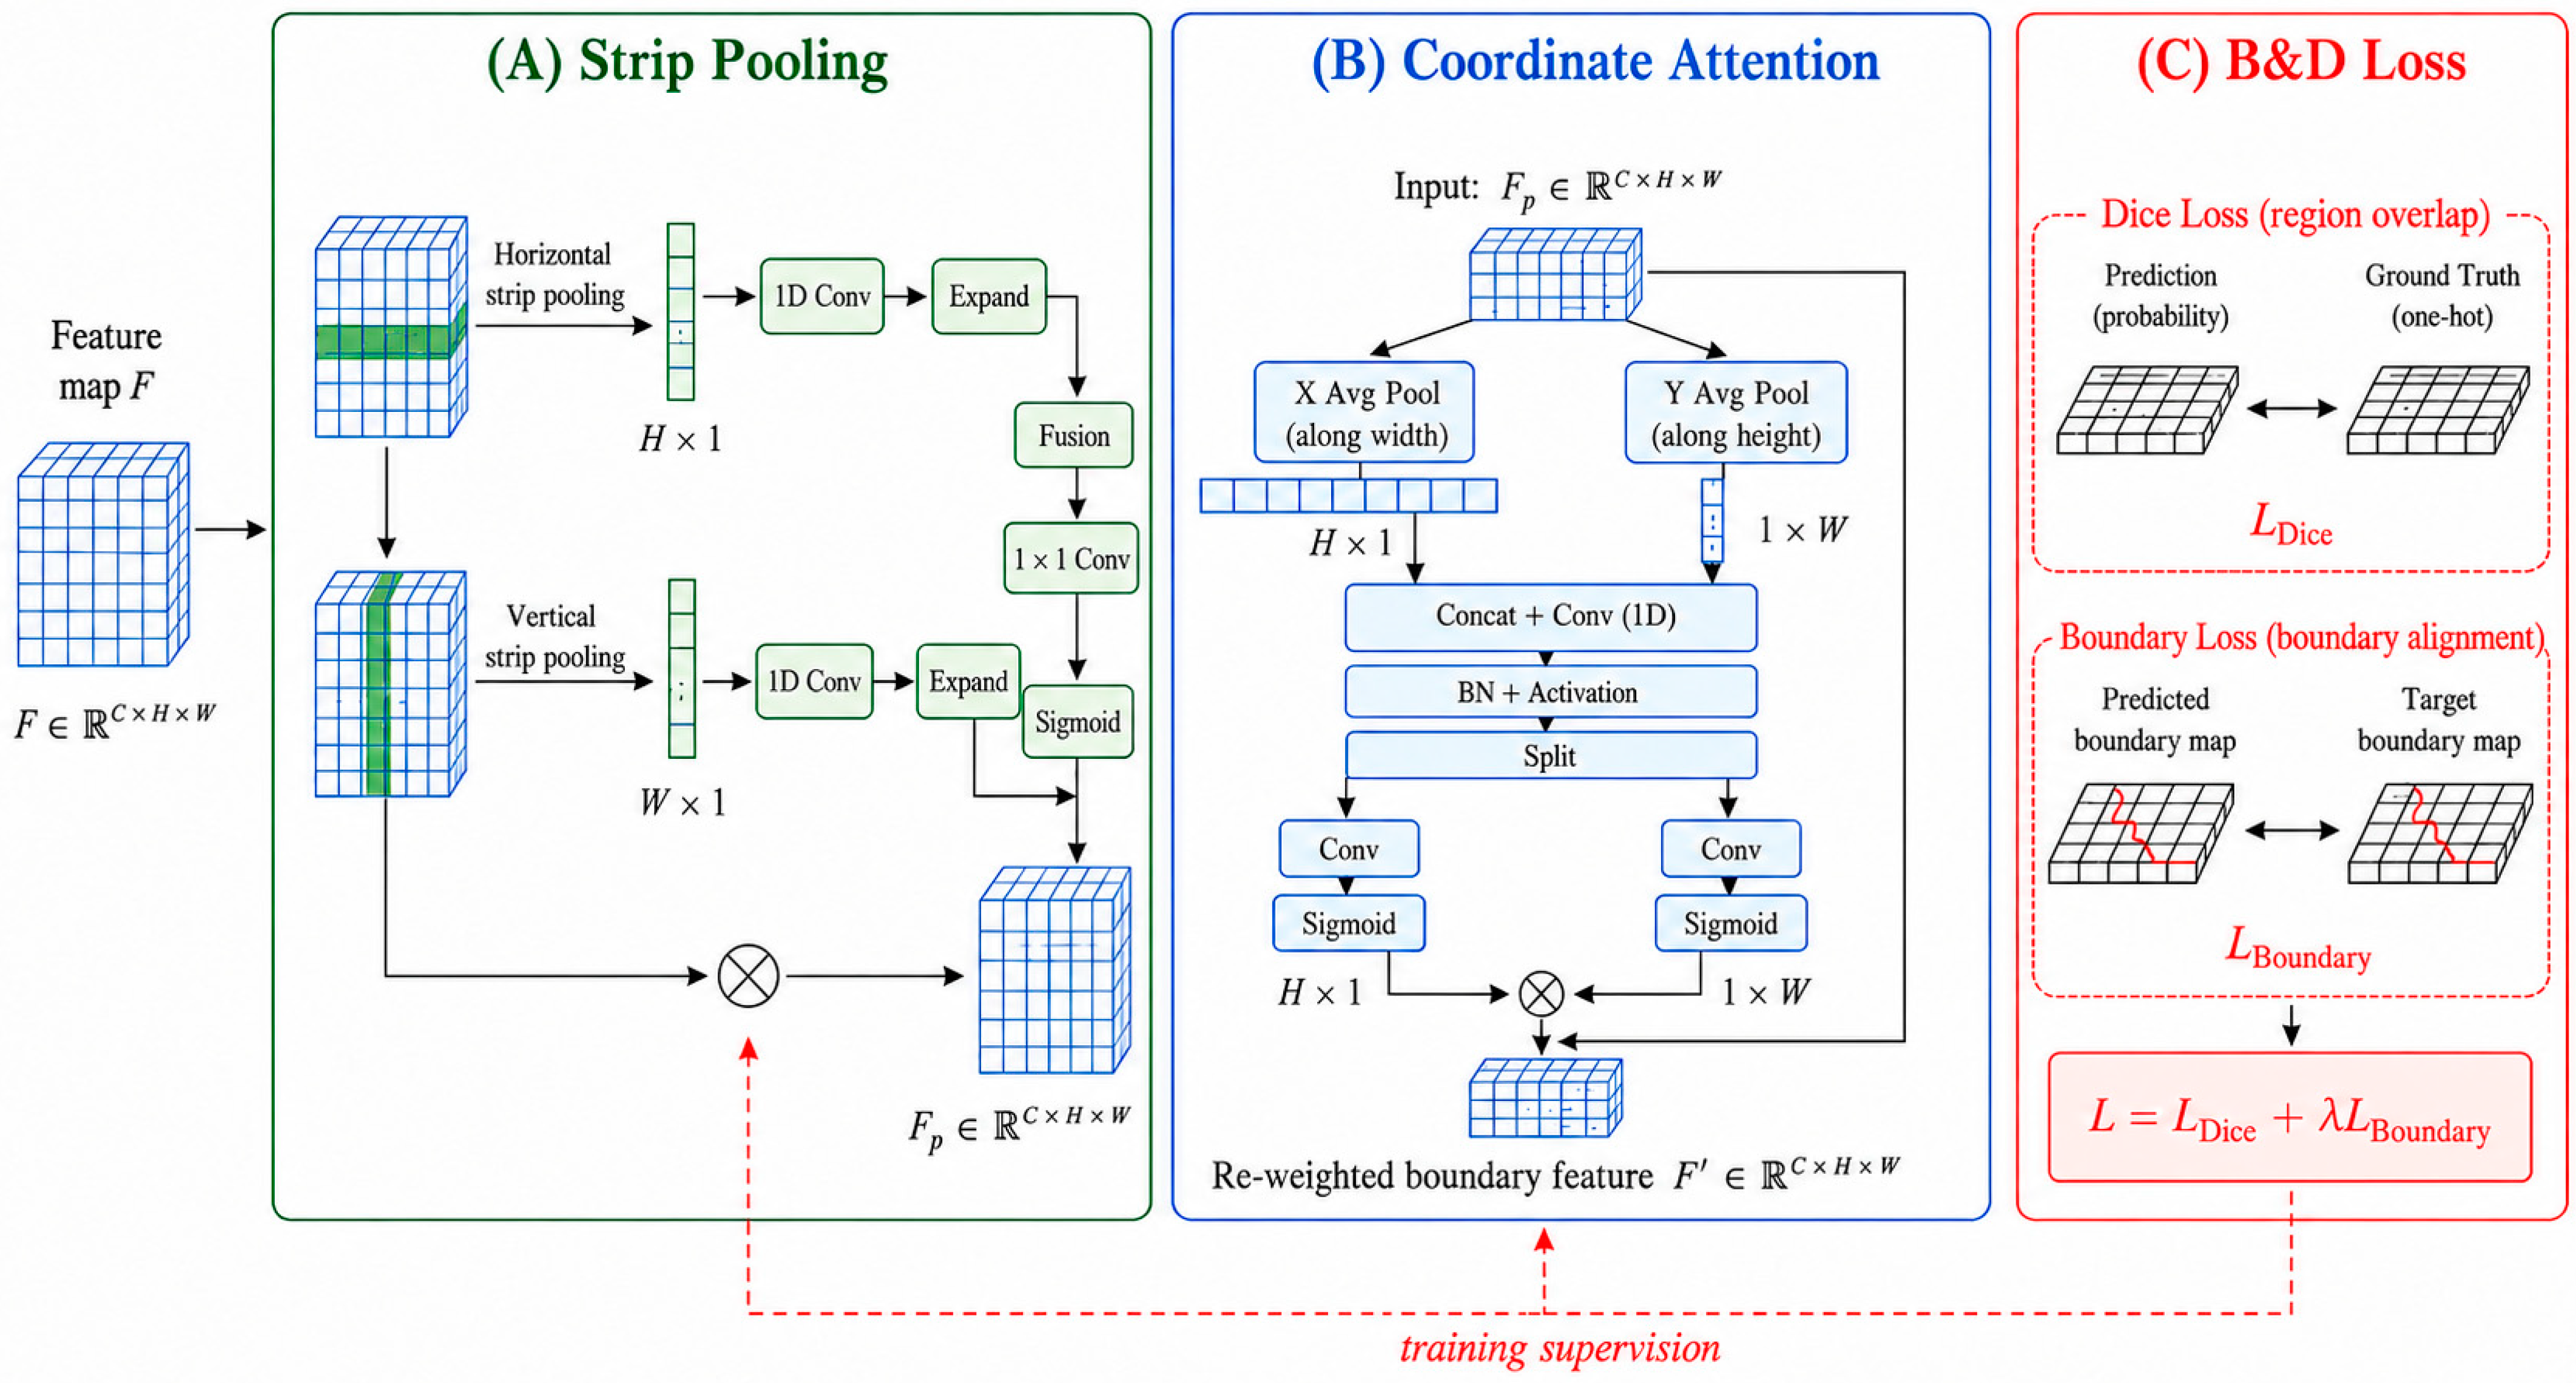
2.2.3. Boundary-Aware Enhancement Modules for Headland Segmentation
2.2.4. Lightweight Training and Model Compression
2.2.5. Evaluation Metrics
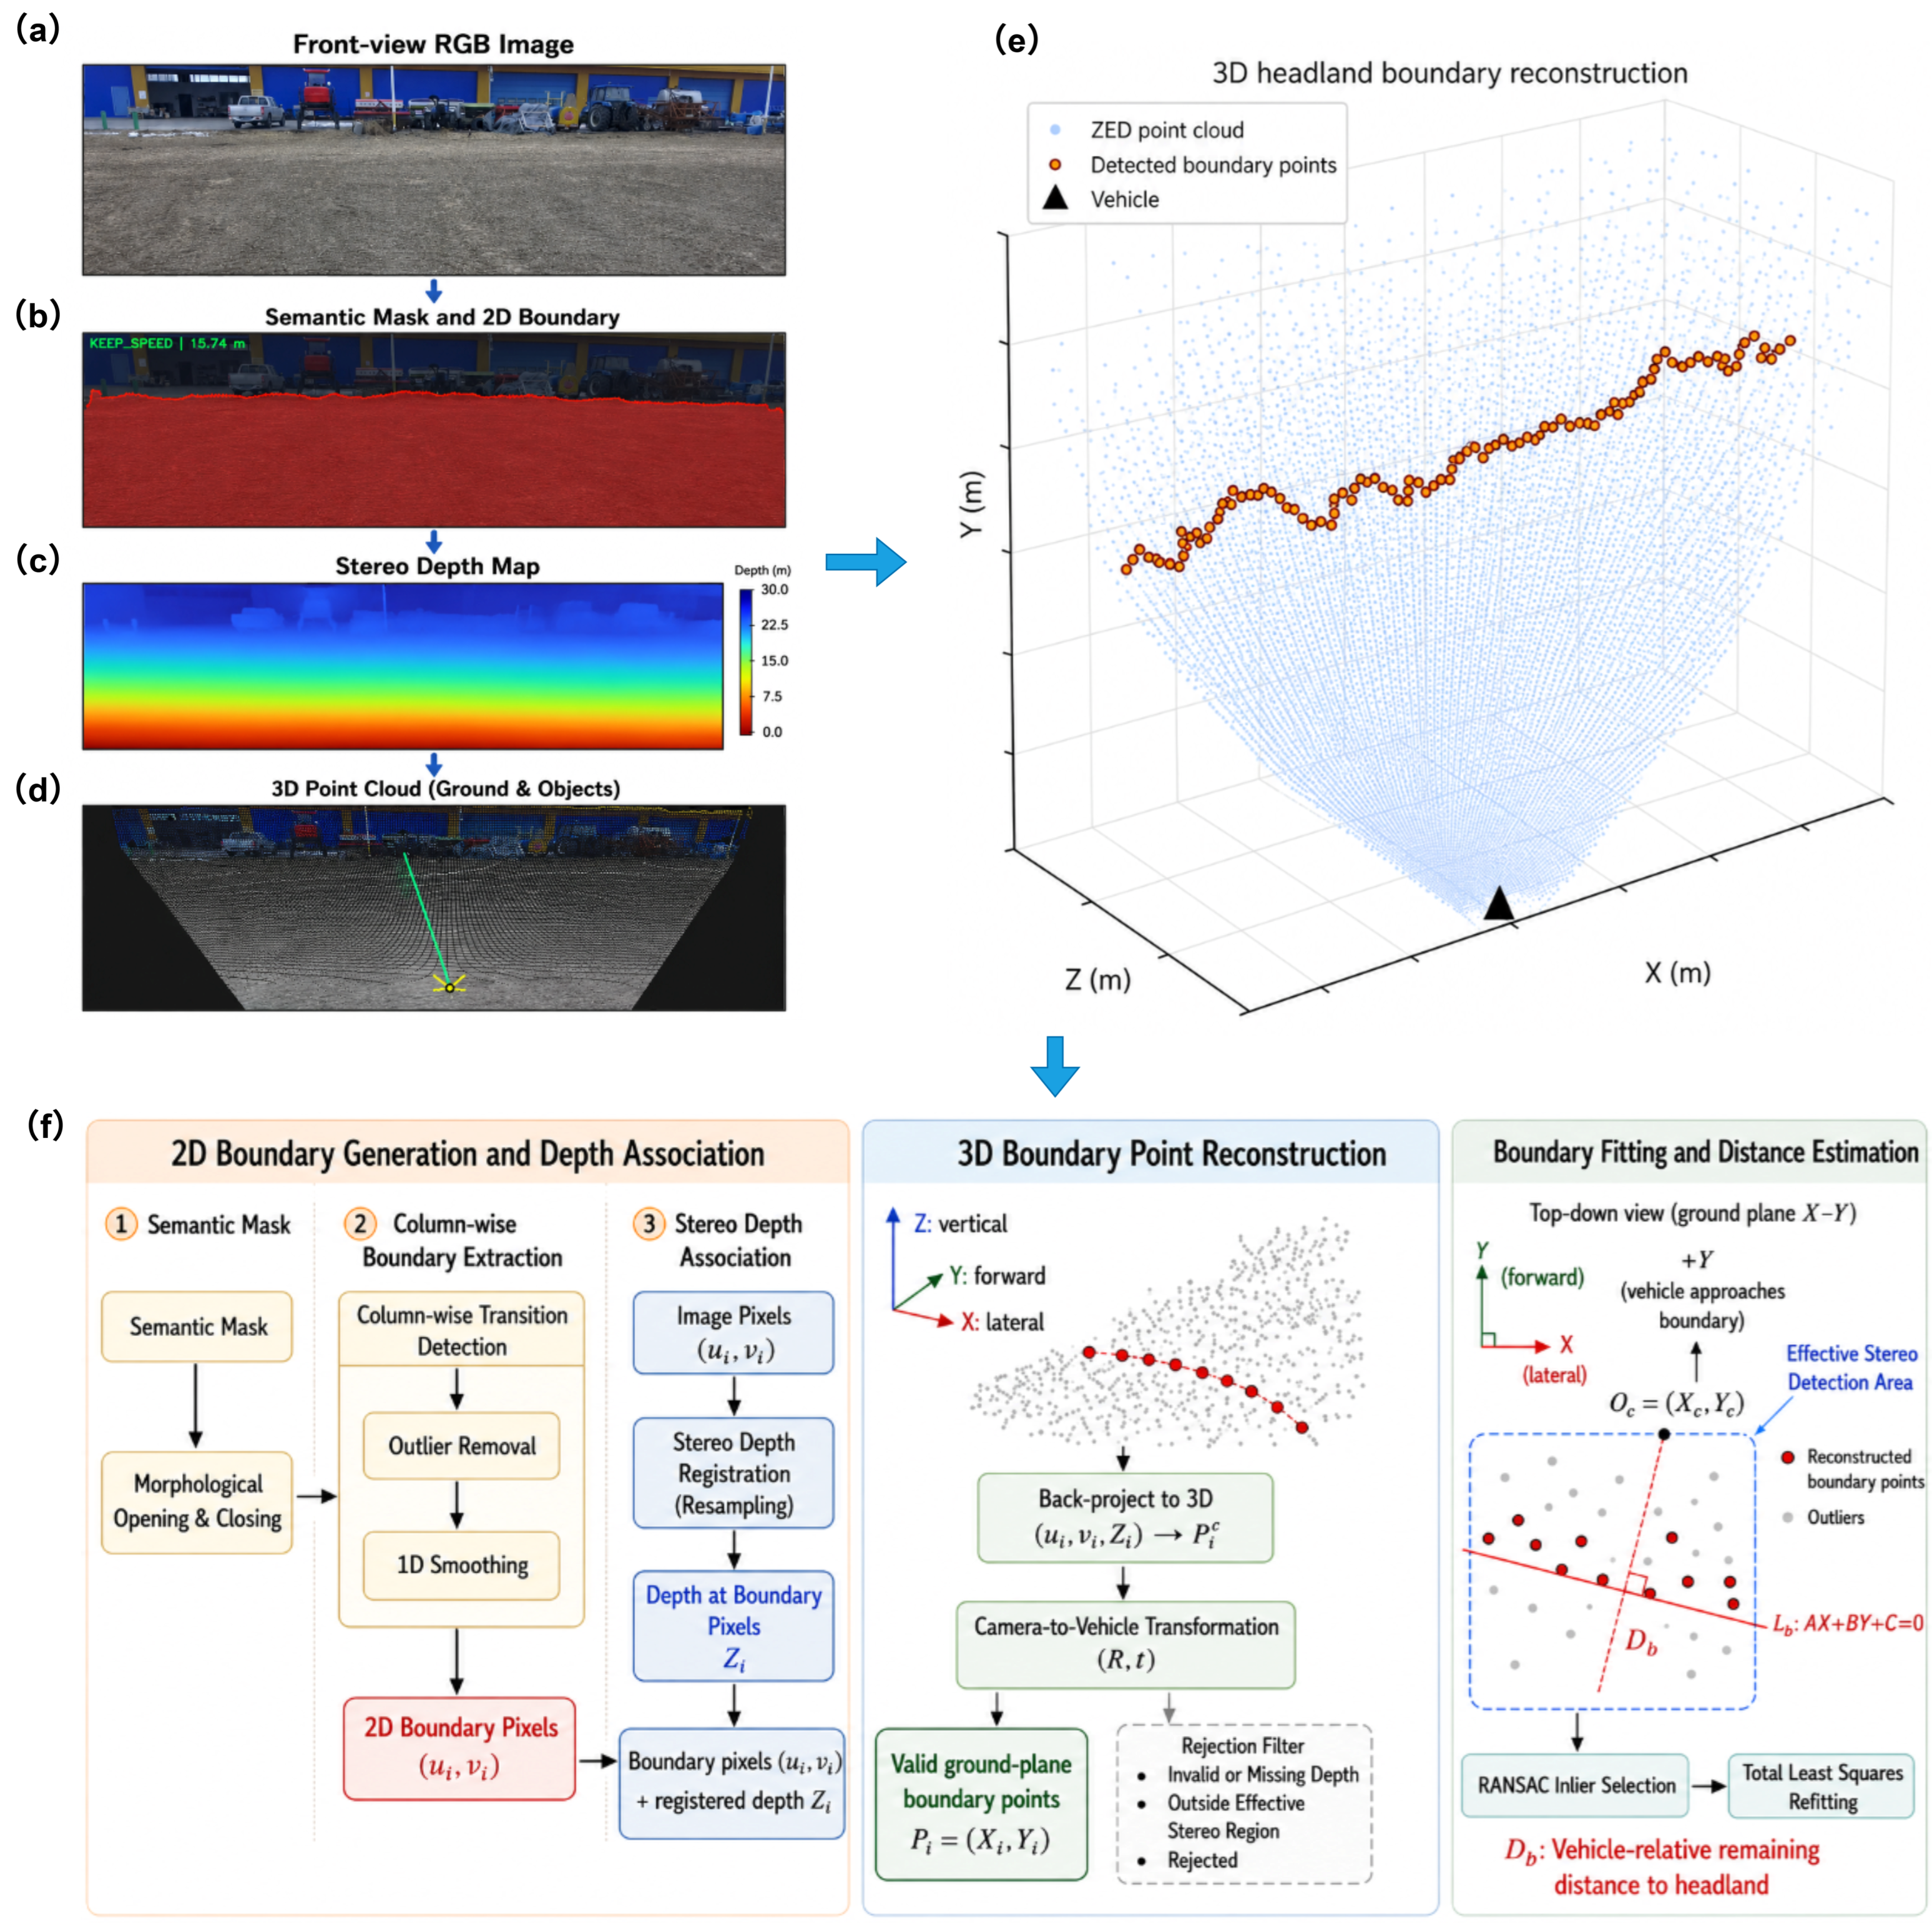
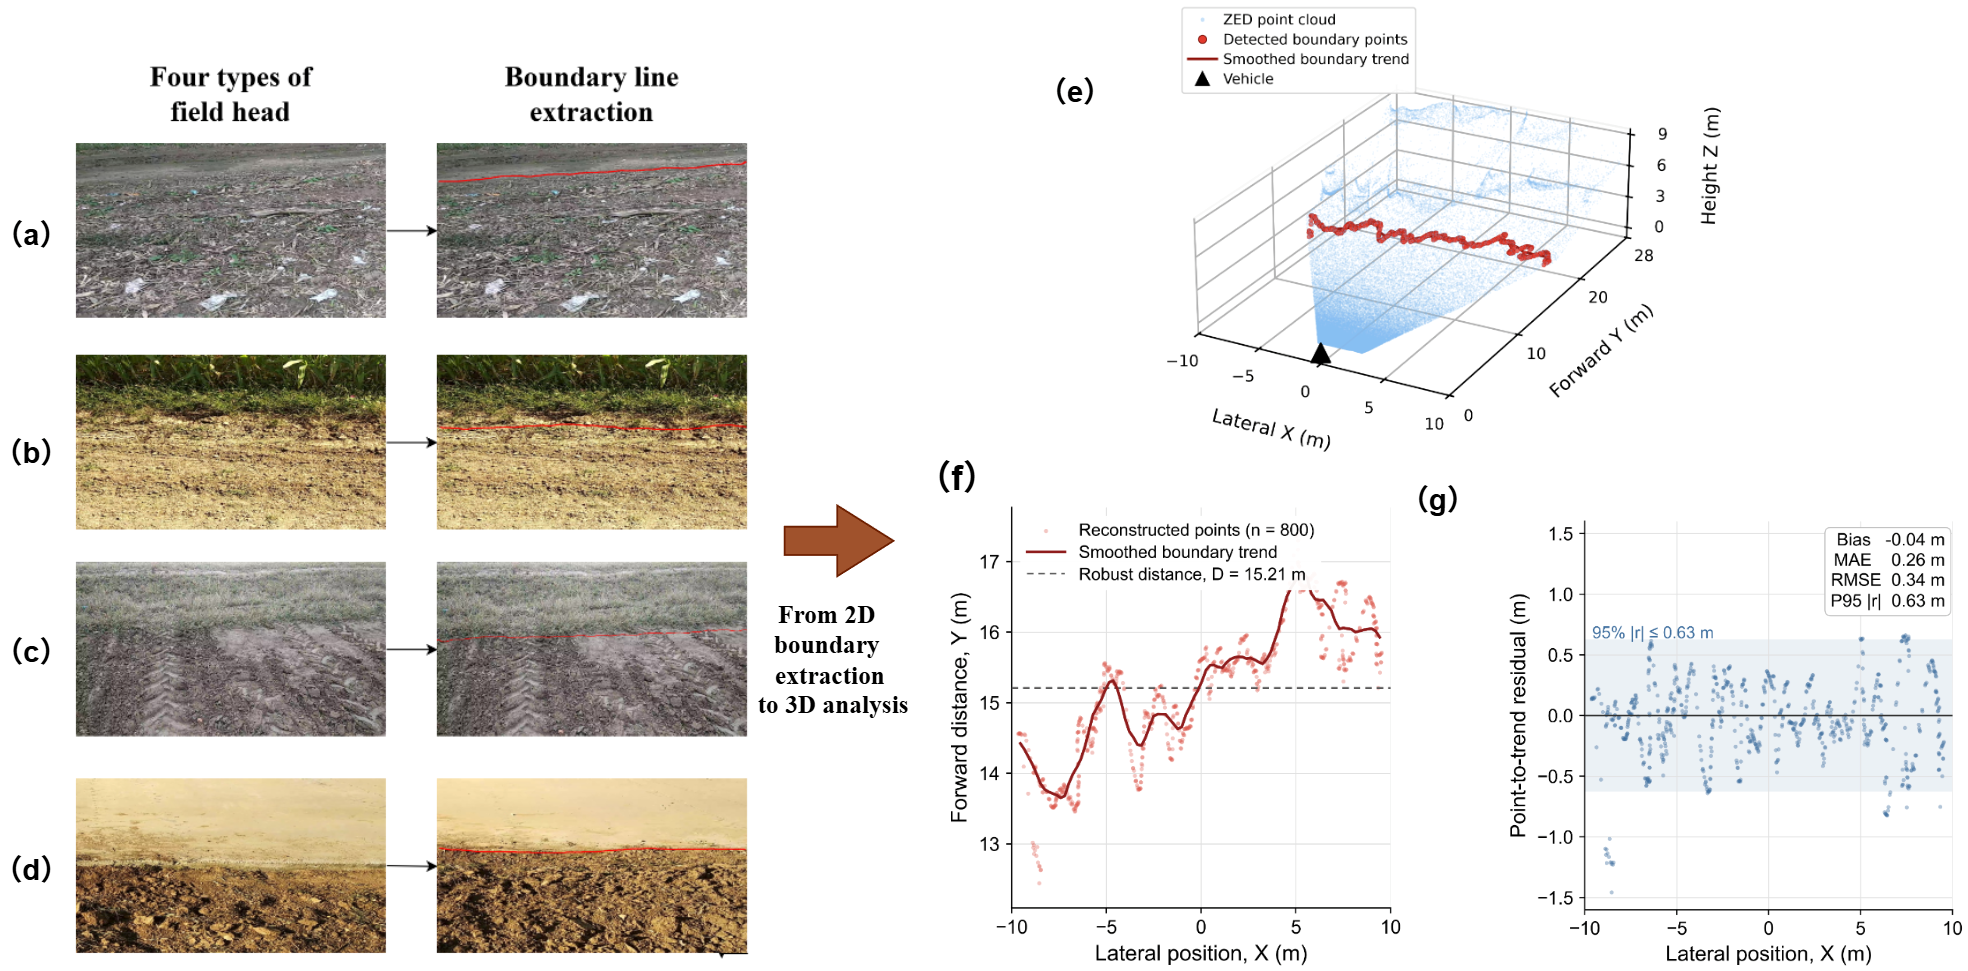
2.3. Three-Dimensional Boundary Reconstruction and Ranging
2.4. Headland Behavioral Decision-Making
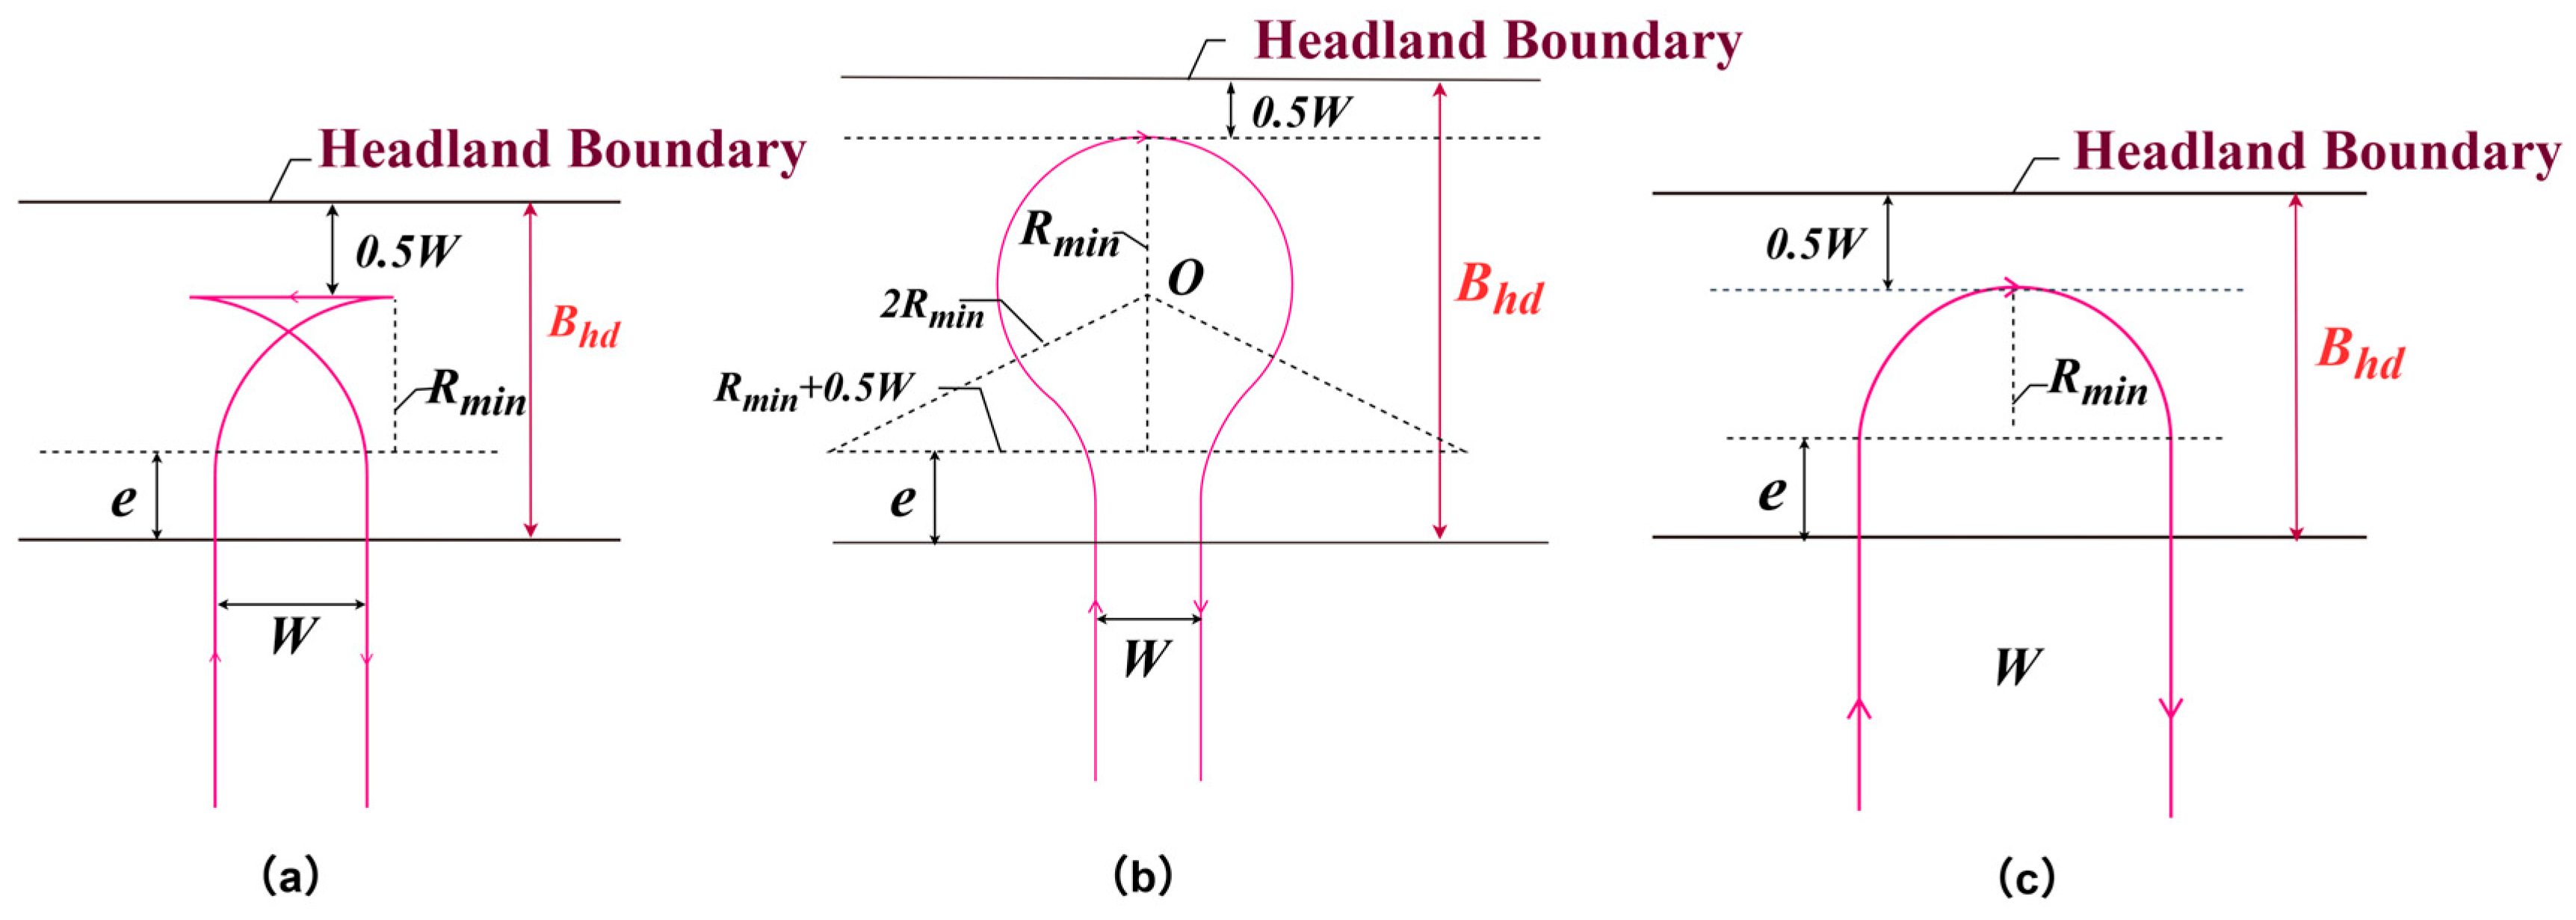
2.4.1. Headland Width Analysis for Typical Turning Patterns
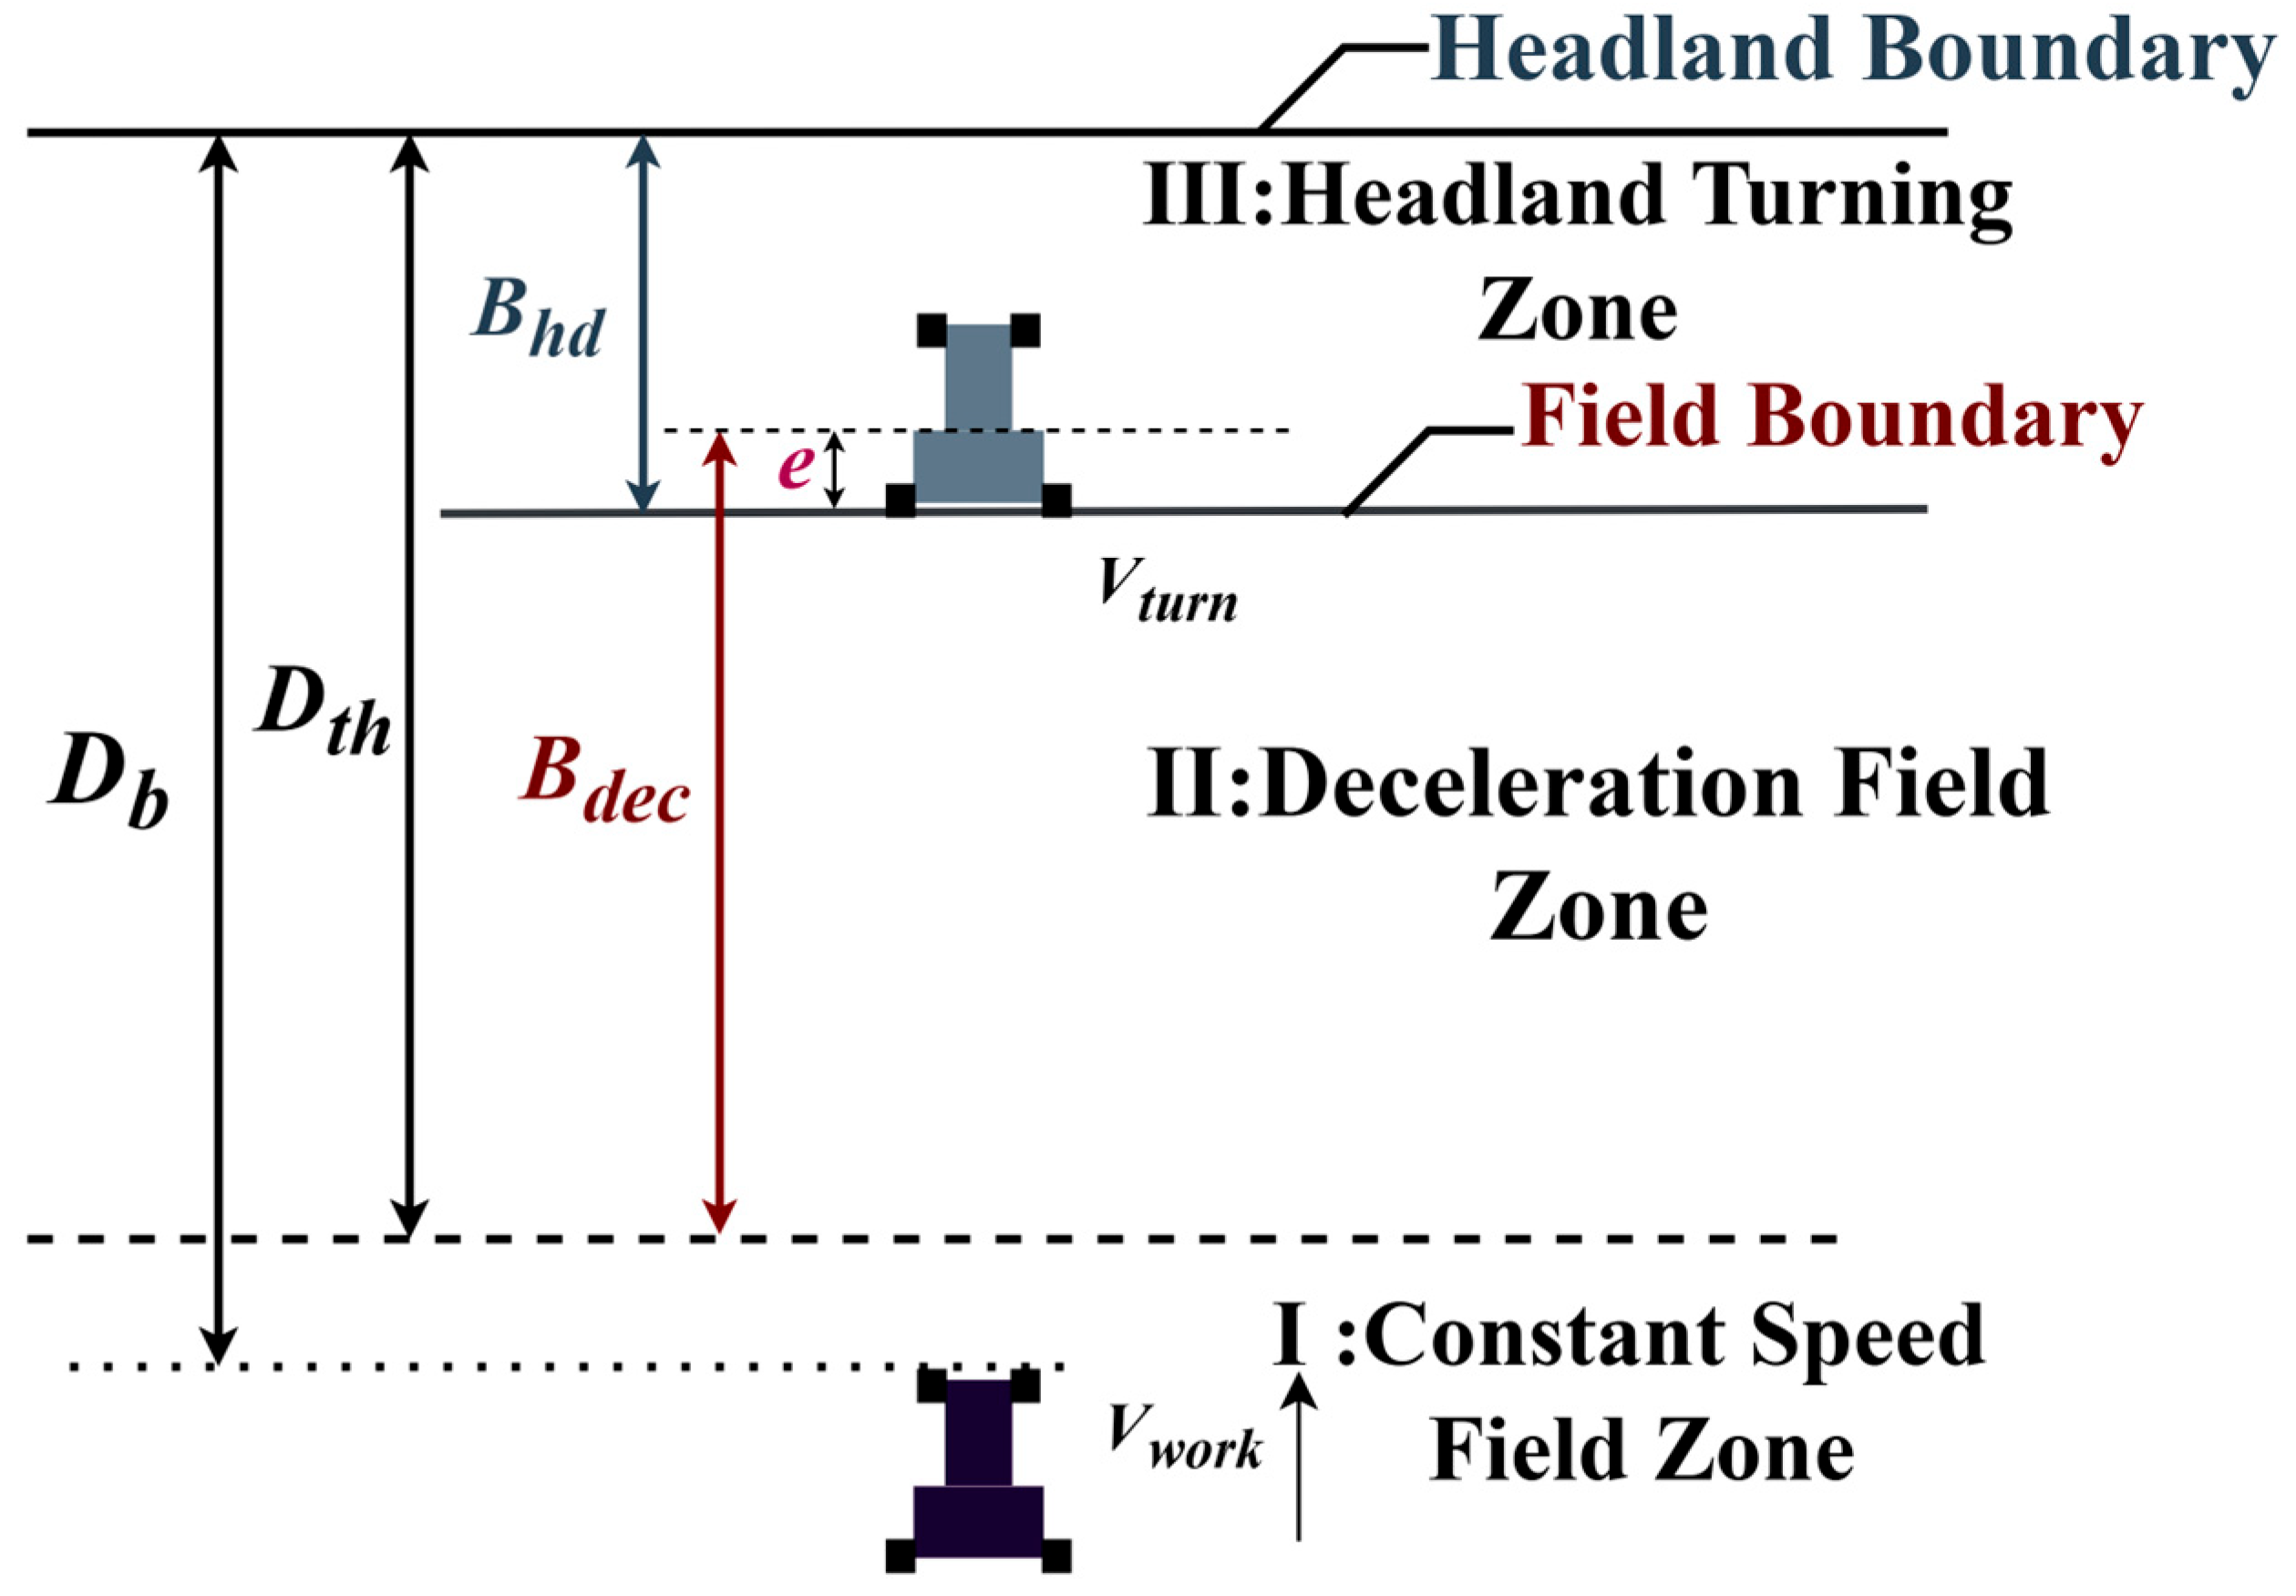
2.4.2. Distance Threshold-Based Headland Decision-Making
- (1)
- When , the agricultural machine maintains the working speed and continues operation;
- (2)
- When , the agricultural machine begins to decelerate with a deceleration rate ;
- (3)
- When , the agricultural machine is decelerating, with the speed reduced from to ;
- (4)
- When , the agricultural machine lifts the implement and begins executing the selected turn type at speed .
2.5. Artificial Intelligence (AI) Use Statement
3. Results
3.1. Evaluation of the Headland Classification Network
3.2. Evaluation of the Image Segmentation Model
3.2.1. Ablation Study
3.2.2. Performance Comparison of Loss Functions
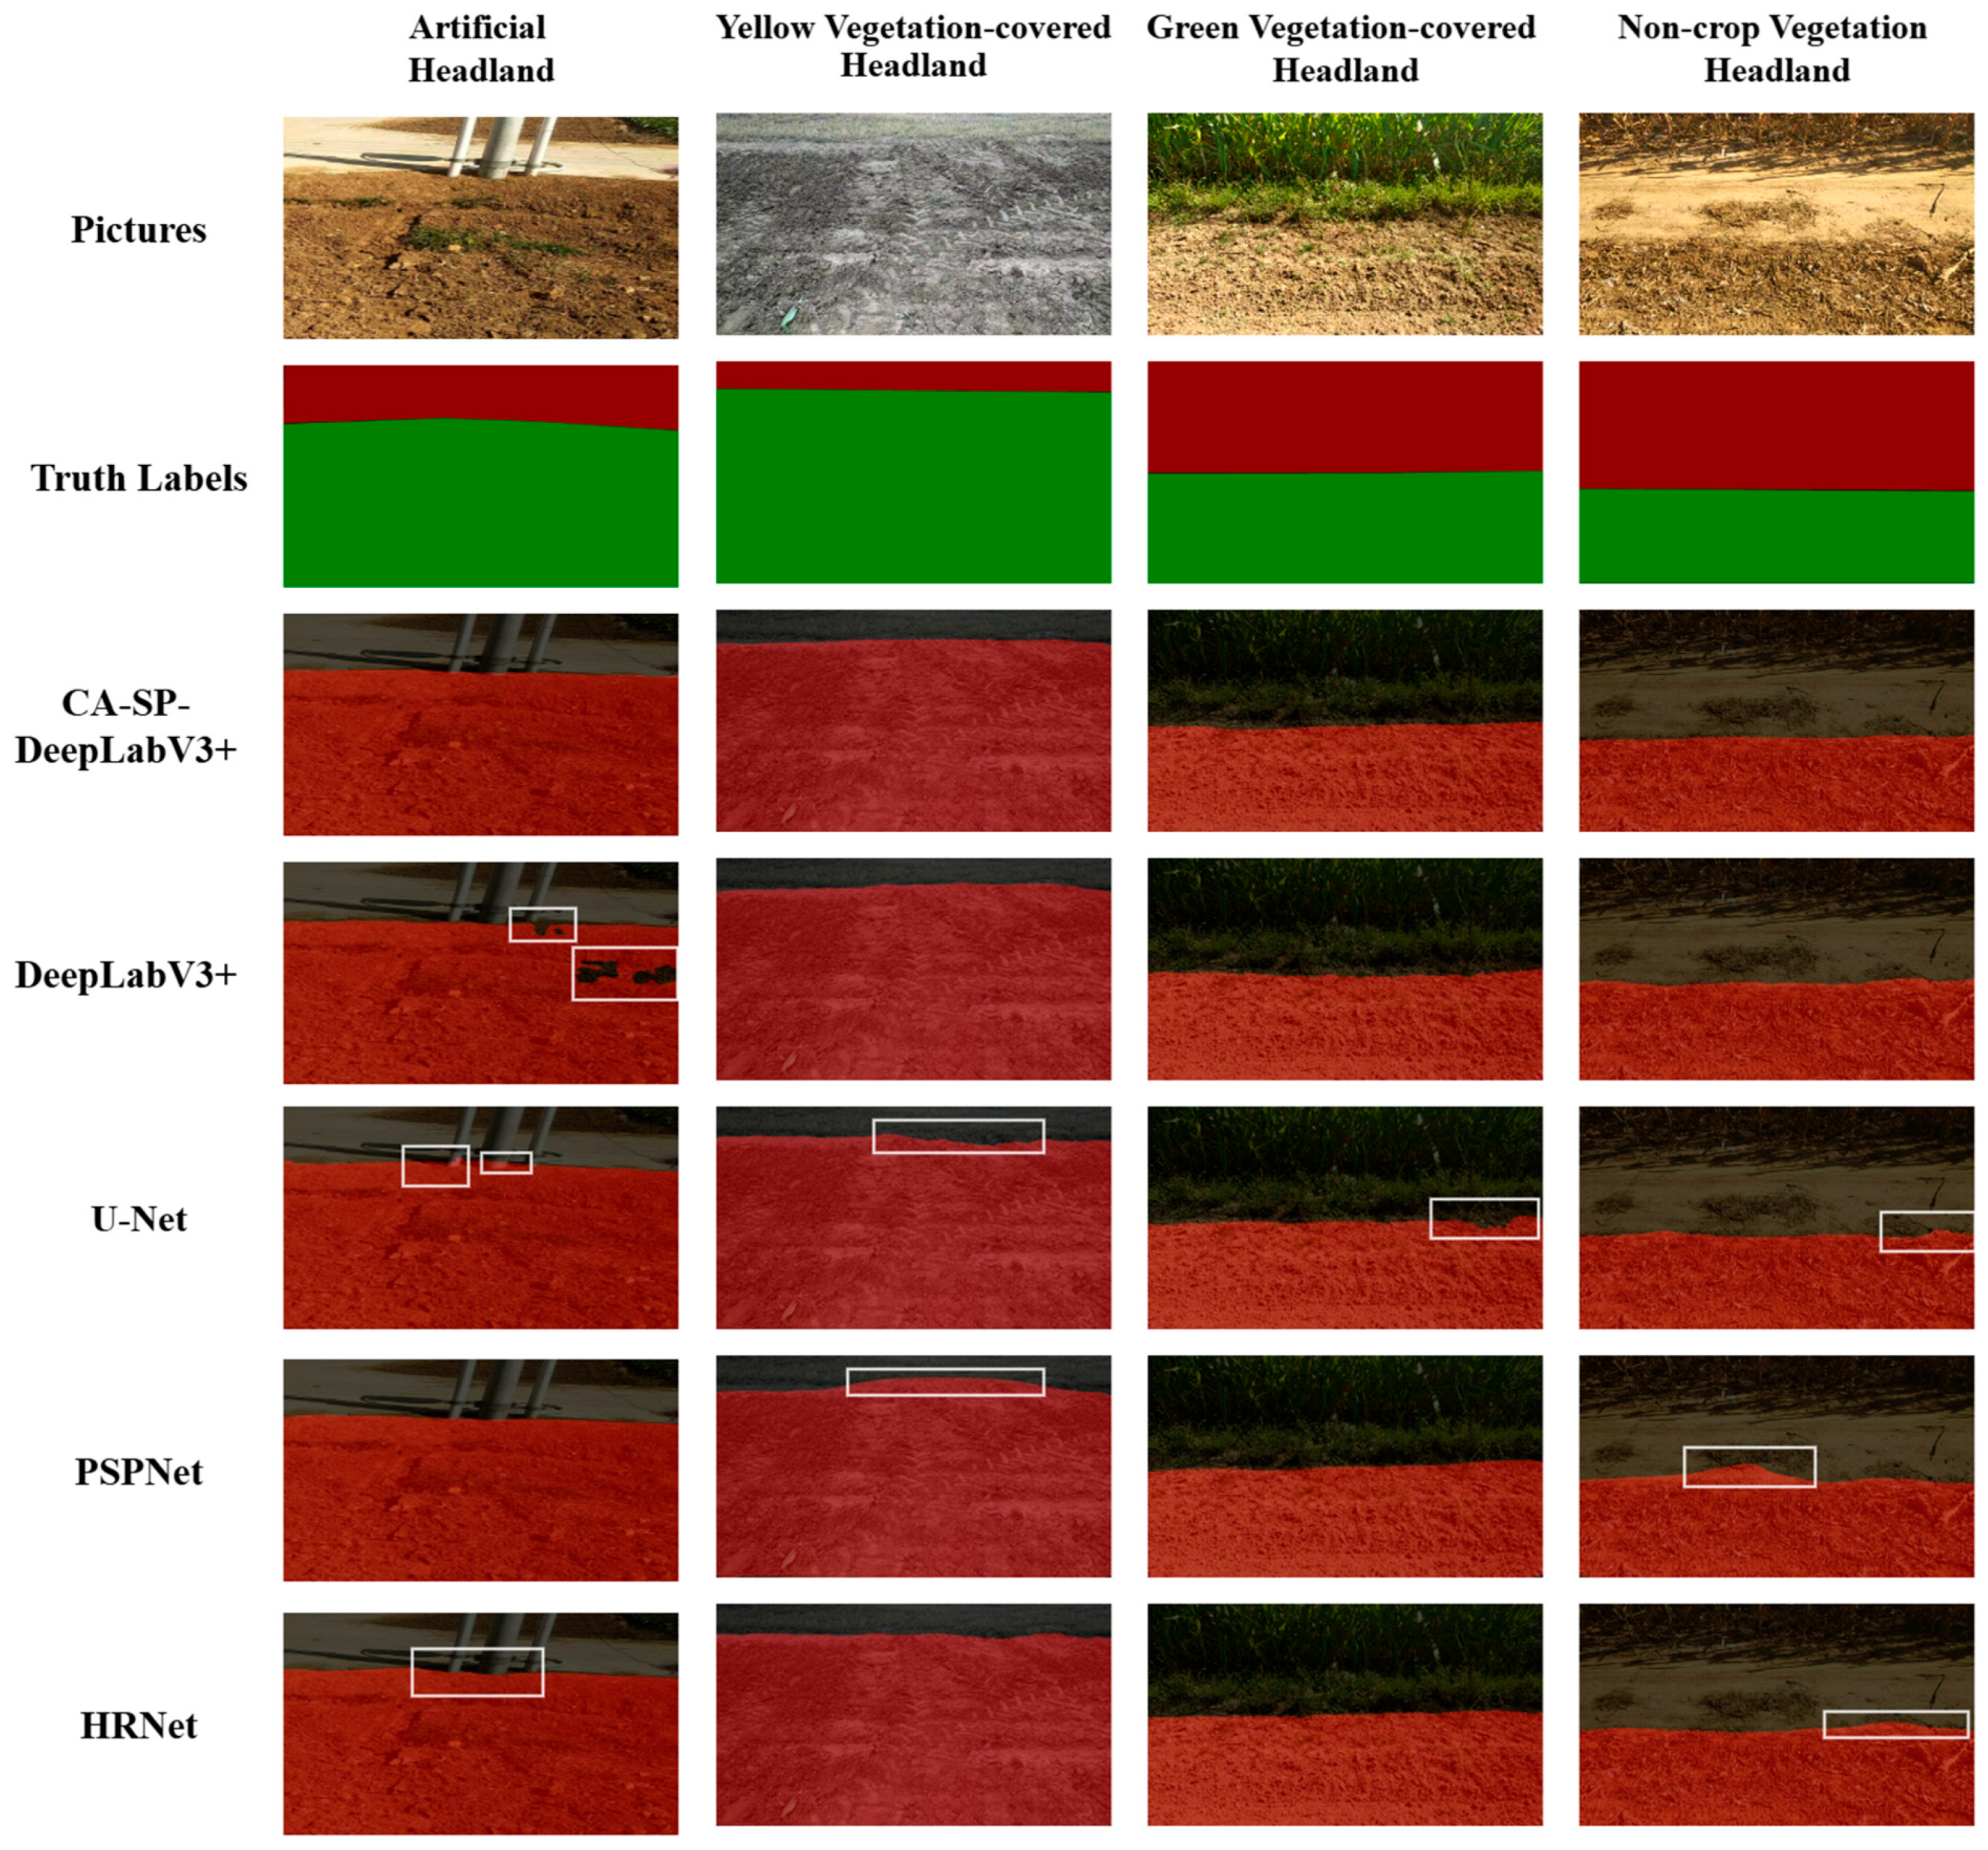
3.2.3. Comparison with Classic Semantic Segmentation Models
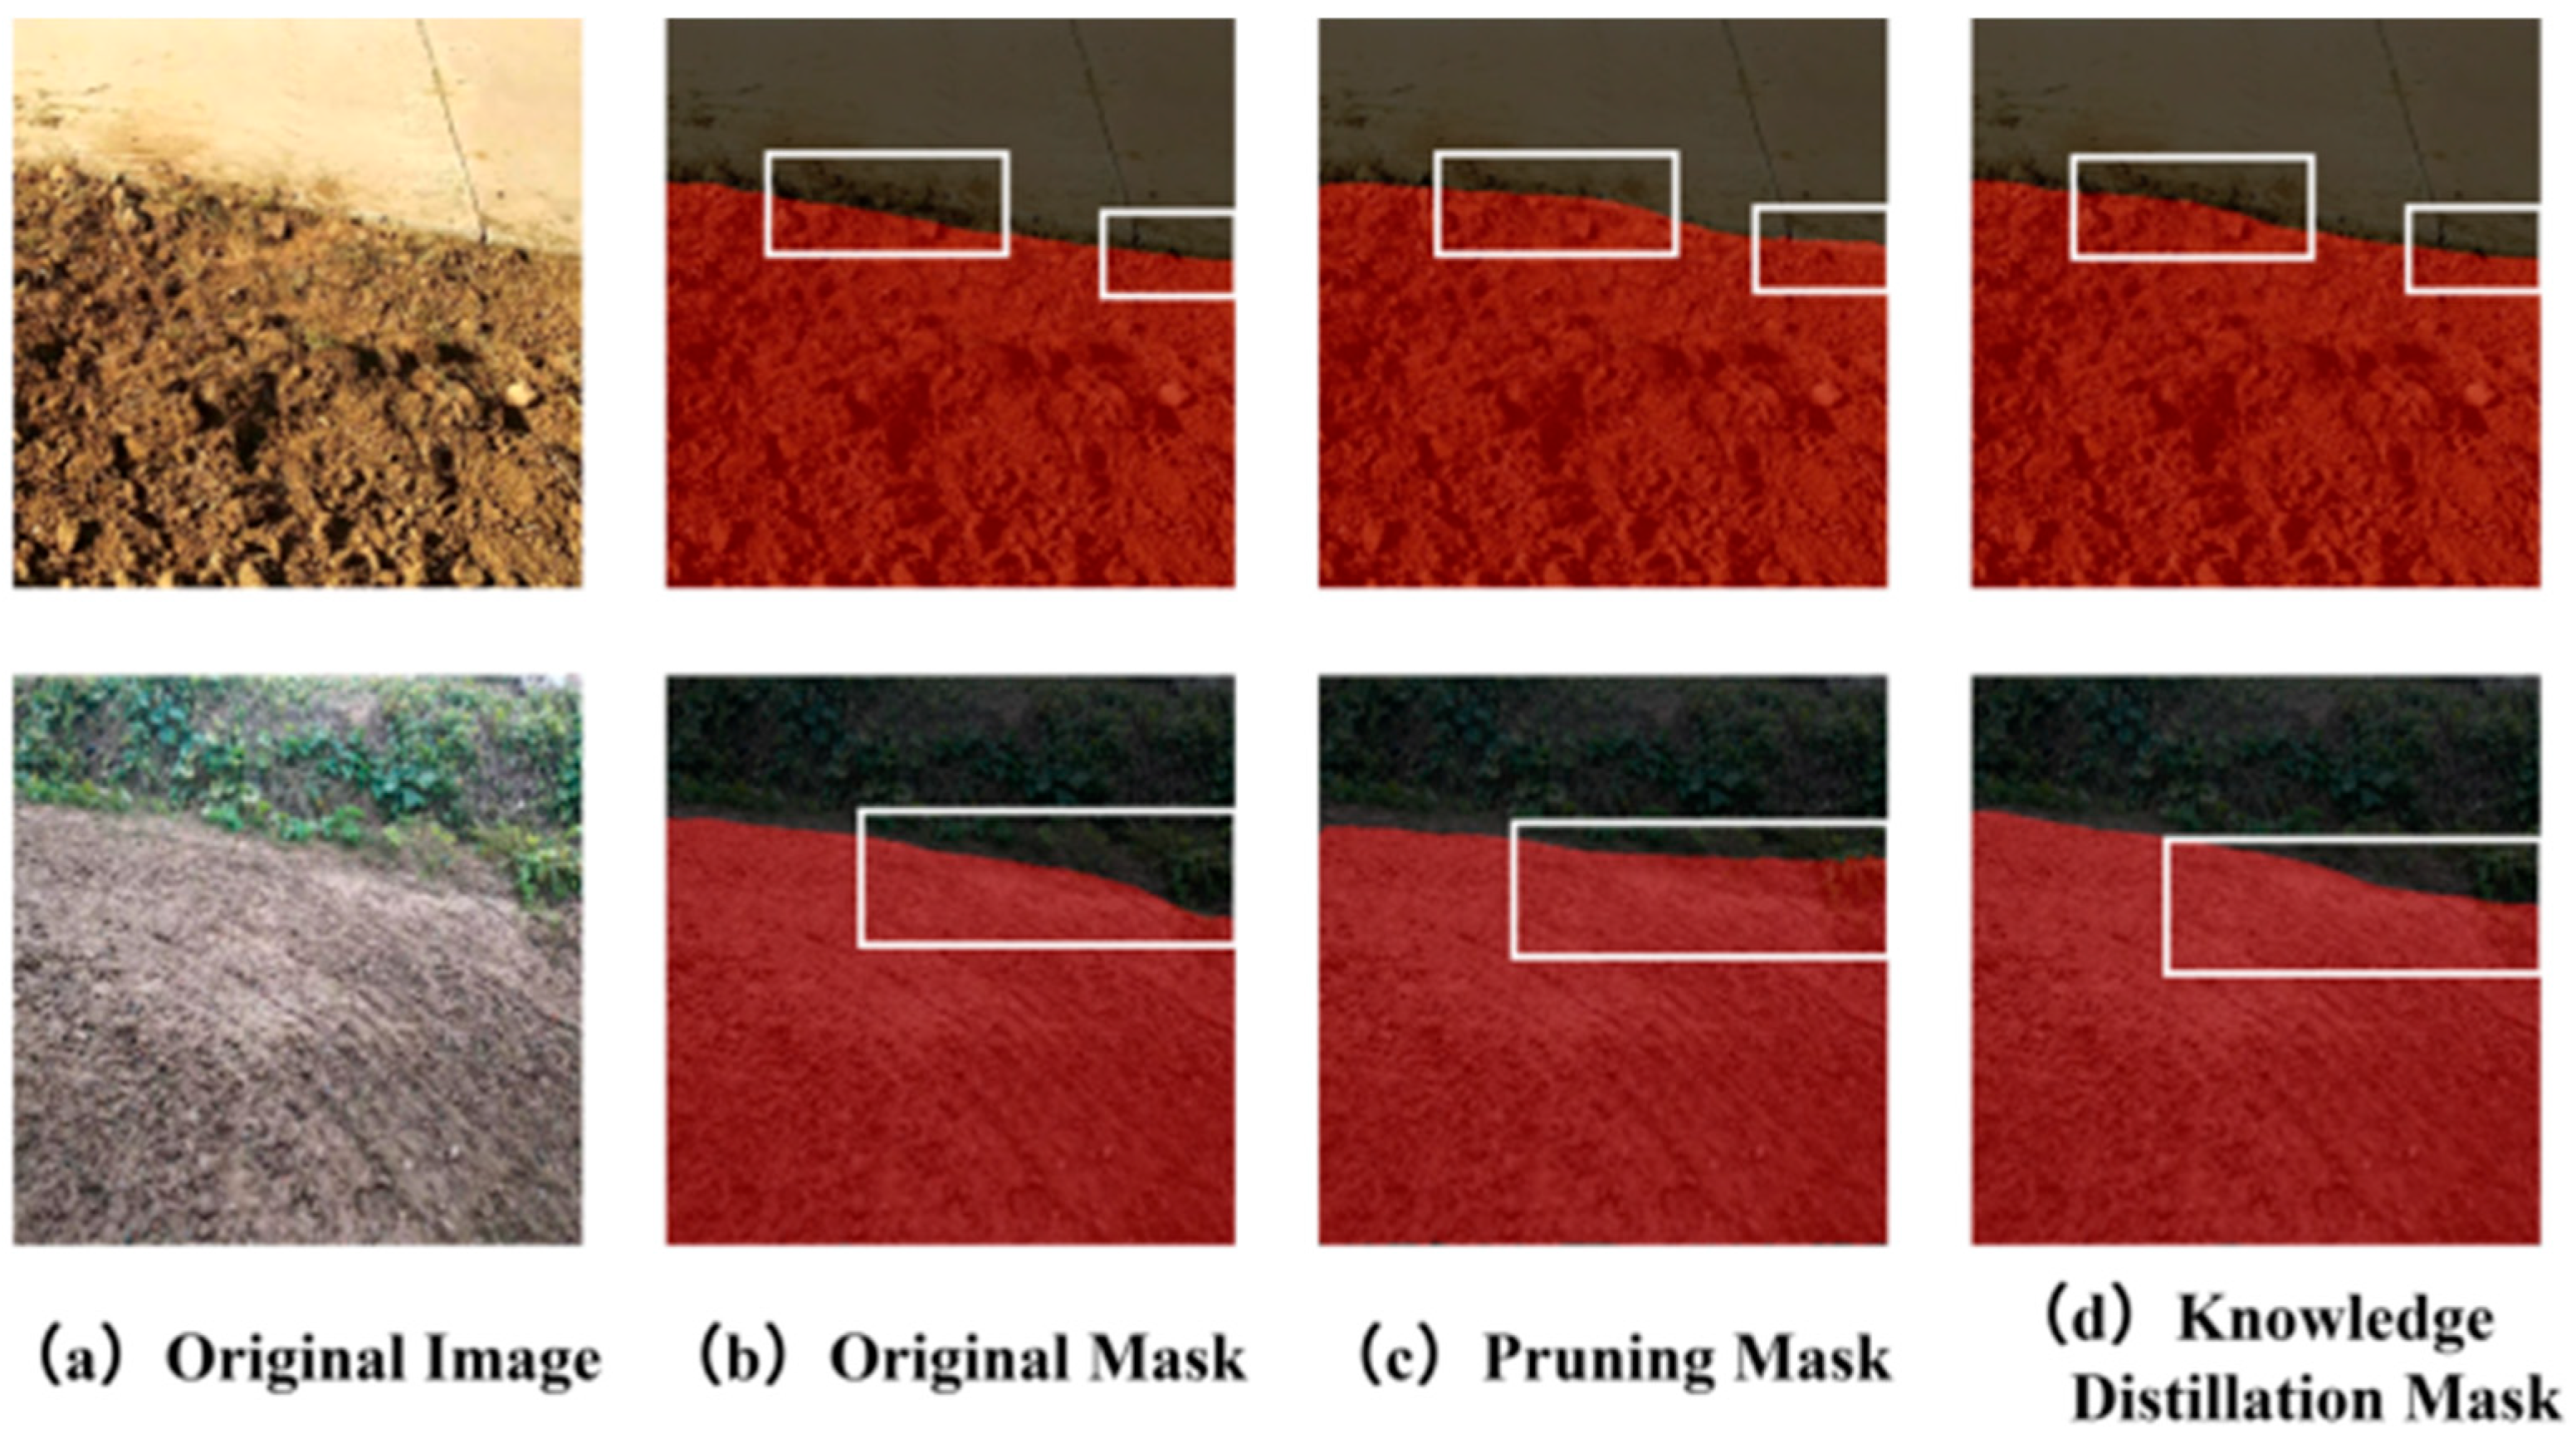
3.2.4. Performance Comparison of Model Pruning and Distillation
3.3. Headland Boundary Extraction and Ranging Analysis
3.4. Headland Turning Decision Test
3.4.1. Headland Turning Width Planning Experiment
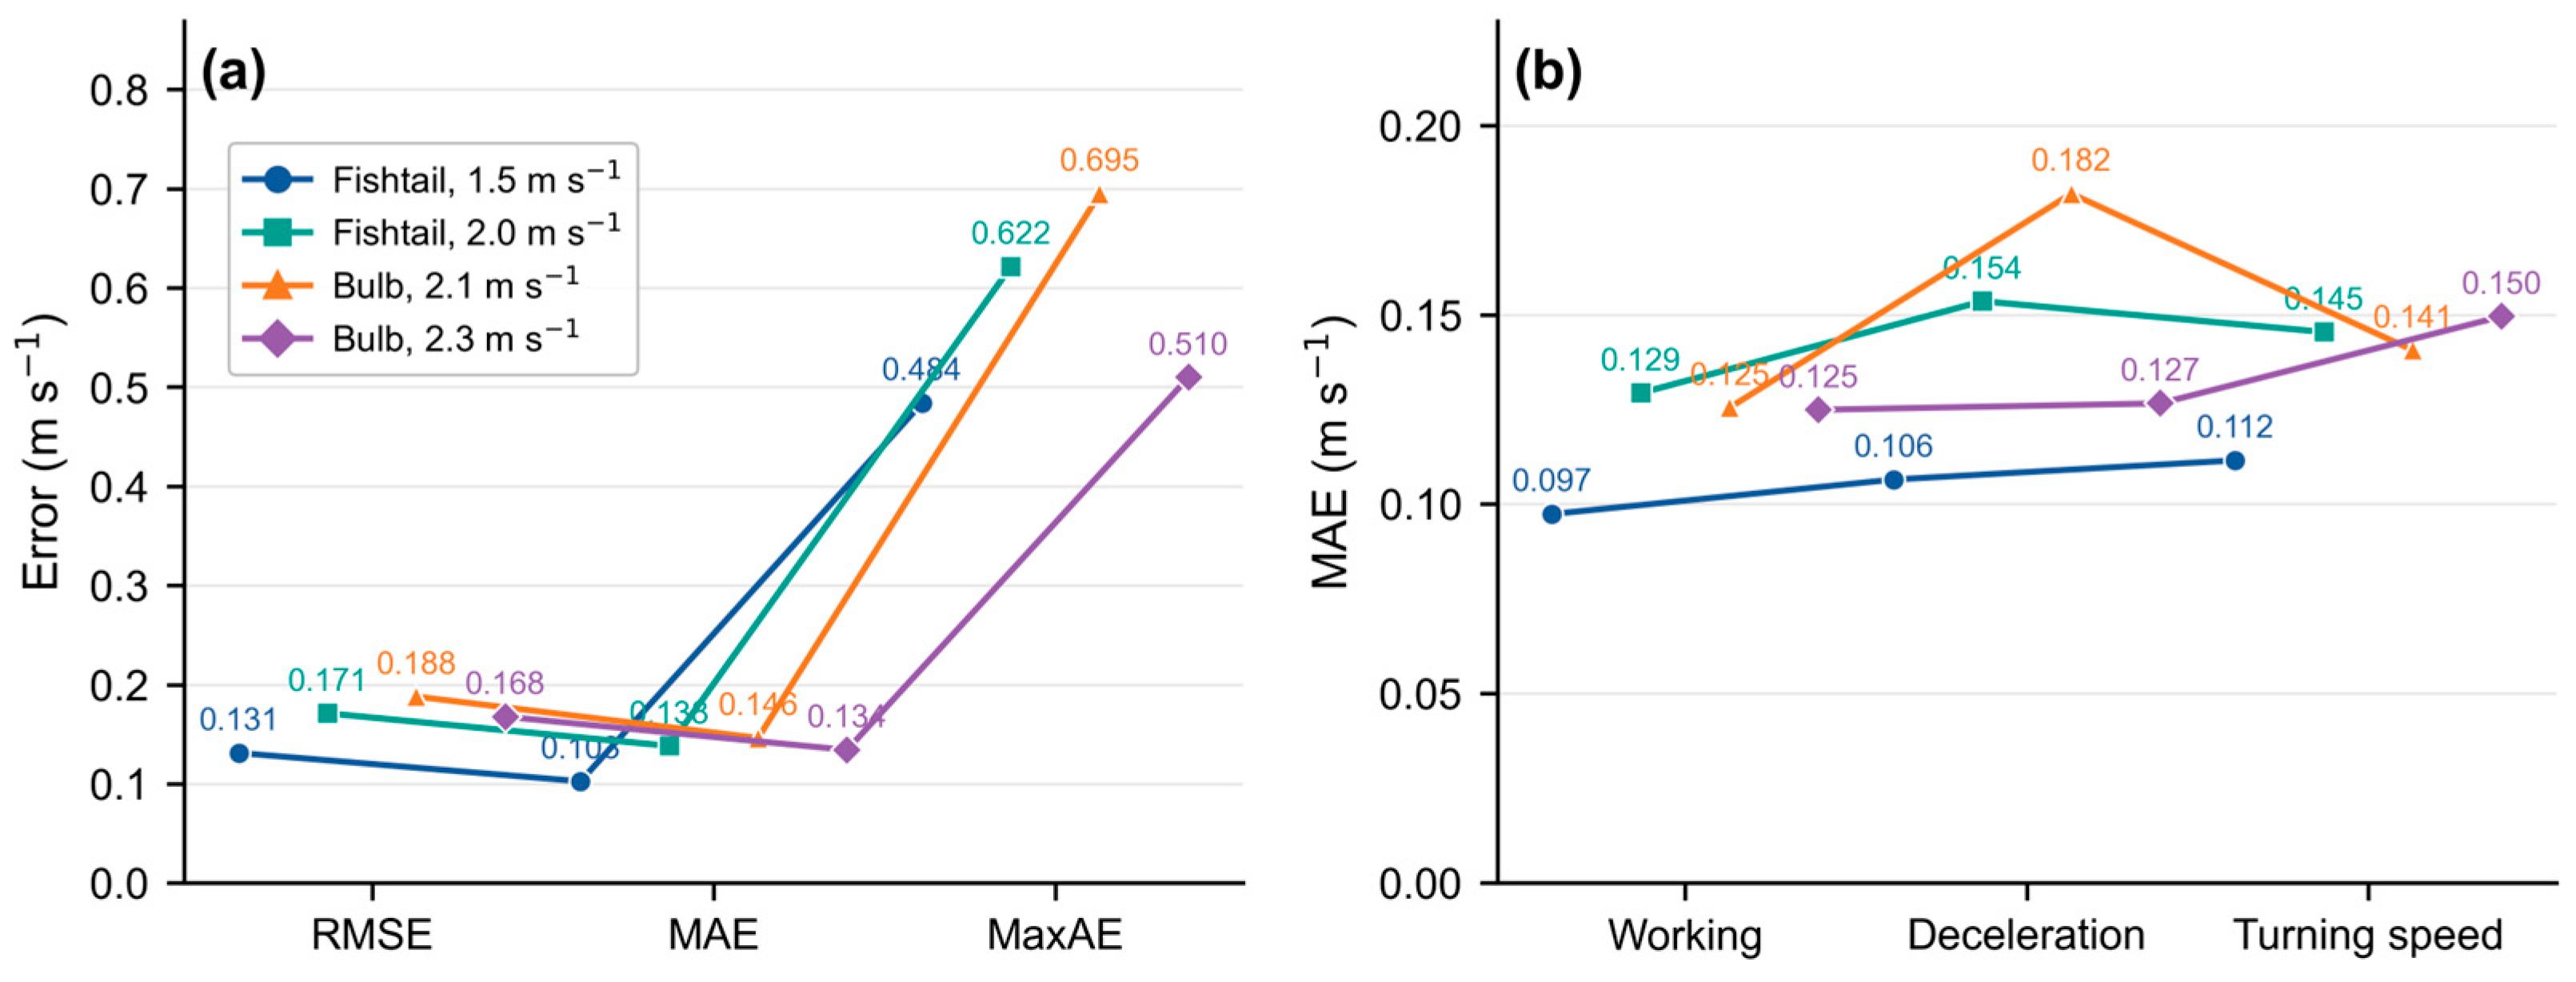
3.4.2. Motion Planning Experiment Based on Headland Distance
4. Discussion
4.1. Boundary-Aware Segmentation and Lightweight Deployment
4.2. Contribution of Binocular Ranging to Decision Reliability
4.3. Spatial Efficiency and Timing of the Turning Decision
4.4. Limitations and Future Development
5. Conclusions
Author Contributions
Funding
Institutional Review Board Statement
Informed Consent Statement
Data Availability Statement
Acknowledgments
Conflicts of Interest
Abbreviations
| 3D | Three-Dimensional |
| ASPP | Atrous Spatial Pyramid Pooling |
| B&D | Boundary and Dice Loss |
| CA | Coordinate Attention |
| CE | Cross-Entropy |
| CPU | Central Processing Unit |
| FLOPs | Floating-Point Operations |
| FN | False Negative |
| FP | False Positive |
| fps | Frames per Second |
| GNSS | Global Navigation Satellite System |
| GPU | Graphics Processing Unit |
| HRNet | High-Resolution Network |
| IoU | Intersection over Union |
| MAE | Mean Absolute Error |
| mIoU | Mean Intersection over Union |
| mPA | Mean Pixel Accuracy |
| PA | Pixel Accuracy |
| RANSAC | Random Sample Consensus |
| RGB-D | Red–Green–Blue and Depth |
| RMSE | Root Mean Square Error |
| SGD | Stochastic Gradient Descent |
| SP | Strip Pooling |
| TN | True Negative |
| TP | True Positive |
References
- Hossain, M.S.; Rahman, M.; Rahman, A.; Kabir, M.M.; Mridha, M.F.; Huang, J.; Shin, J. Automatic navigation and self-driving technology in agricultural machinery: A state-of-the-art systematic review. IEEE Access 2025, 13, 94370–94401. [Google Scholar] [CrossRef] [Scilit]
- Meng, Z.; Wang, H.; Fu, W.; Liu, M.; Yin, Y.; Zhao, C. Research status and prospects of agricultural machinery autonomous driving. Trans. Chin. Soc. Agric. Mach. 2023, 54, 1–16. (In Chinese) [Google Scholar] [CrossRef]
- Yang, X.; Zhong, J.; Lin, K.; Wu, J.; Chen, J.; Si, H. Research progress on binocular stereo vision technology and its applications in smart agriculture. Trans. Chin. Soc. Agric. Eng. 2025, 41, 27–39. (In Chinese) [Google Scholar] [CrossRef]
- Chen, Y.; Zhang, M.; Ma, W.; Liu, Z.; Ji, Y. Positioning method of integrated navigation based on GPS and machine vision. Trans. Chin. Soc. Agric. Eng. 2011, 27, 126–130. (In Chinese) [Google Scholar] [CrossRef]
- Ren, Y.; Zhang, B.; Li, Y.; Chen, C.; Li, W.; Ma, Y. Computer vision-based steering path visualization of headlands in soybean fields. Front. Plant Sci. 2025, 16, 1673567. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Huang, P.; Zhu, L.; Zhang, Z.; Yang, C. Row end detection and headland turning control for an autonomous banana-picking robot. Machines 2021, 9, 103. [Google Scholar] [CrossRef] [Scilit]
- Li, J.; Chen, B.; Liu, Y.; Zha, T. Detection for navigation route for cotton harvester based on machine vision. Trans. Chin. Soc. Agric. Eng. 2013, 29, 11–19. (In Chinese) [Google Scholar]
- Wang, Q.; Liu, H.; Yang, P.; Meng, Z. Detection method of headland boundary line based on machine vision. Trans. Chin. Soc. Agric. Mach. 2020, 51, 18–25. (In Chinese) [Google Scholar] [CrossRef]
- Qiao, Y.; Peng, S.; Meng, Z.; Wang, Q.; Liu, S. Detection system of headland boundary line based on machine vision. J. Agric. Mech. Res. 2022, 44, 24–30. (In Chinese) [Google Scholar] [CrossRef]
- Qiao, Y.; Liu, H.; Meng, Z.; Chen, J.; Ma, L. Method for the automatic recognition of cropland headland images based on deep learning. Int. J. Agric. Biol. Eng. 2023, 16, 216–224. [Google Scholar] [CrossRef] [Scilit]
- Liu, H.; Li, K.; Ma, L.; Meng, Z. Headland identification and ranging method for autonomous agricultural machines. Agriculture 2024, 14, 243. [Google Scholar] [CrossRef] [Scilit]
- He, Y.; Zhang, X.; Zhang, Z.; Fang, H. Automated detection of boundary line in paddy field using MobileV2-UNet and RANSAC. Comput. Electron. Agric. 2022, 194, 106697. [Google Scholar] [CrossRef] [Scilit]
- Ji, J.; Han, Z.; Zhao, K.; Li, Q.; Du, S. Detection of the farmland plow areas using RGB-D images with an improved YOLOv5 model. Int. J. Agric. Biol. Eng. 2024, 17, 156–165. [Google Scholar] [CrossRef] [Scilit]
- Li, D.; Li, B.; Long, S.; Feng, H.; Wang, Y.; Wang, J. Robust detection of headland boundary in paddy fields from continuous RGB-D images using hybrid deep neural networks. Comput. Electron. Agric. 2023, 207, 107713. [Google Scholar] [CrossRef] [Scilit]
- Liu, G.; Jin, C.; Ni, Y.; Yang, T.; Liu, Z. UCIW-YOLO: Multi-category and high-precision obstacle detection model for agricultural machinery in unstructured farmland environments. Expert Syst. Appl. 2025, 294, 128686. [Google Scholar] [CrossRef] [Scilit]
- Soitinaho, R.; Väyrynen, V.; Oksanen, T. Heuristic cooperative coverage path planning for multiple autonomous agricultural field machines performing sequentially dependent tasks of different working widths and turn characteristics. Biosyst. Eng. 2024, 242, 16–28. [Google Scholar] [CrossRef] [Scilit]
- He, Z.; Bao, Y.; Yu, Q.; Lu, P.; He, Y.; Liu, Y. Dynamic path planning method for headland turning of unmanned agricultural vehicles. Comput. Electron. Agric. 2023, 206, 107699. [Google Scholar] [CrossRef] [Scilit]
- Wu, T.; Guo, H.; Zhou, W.; Gao, G.; Wang, X.; Yang, C. Navigation path extraction for farmland headlands via red-green-blue and depth multimodal fusion based on an improved DeepLabV3+ model. Eng. Appl. Artif. Intell. 2025, 151, 110681. [Google Scholar] [CrossRef] [Scilit]
- Liu, Z.; Wu, X.; Gao, W.; Ning, F.; Zhang, W.; He, J.; Liu, M.; Chen, X.; Fang, P. Research on a vision navigation system for rice transplanters based on machine vision fused with GNSS. Biosyst. Eng. 2026, 262, 104354. [Google Scholar] [CrossRef] [Scilit]
- Backman, J.; Piirainen, P.; Oksanen, T. Smooth turning path generation for agricultural vehicles in headlands. Biosyst. Eng. 2015, 139, 76–86. [Google Scholar] [CrossRef] [Scilit]
- Chen, T.; Xu, L.; Ahn, H.S.; Lu, E.; Liu, Y.; Xu, R. Evaluation of headland turning types of adjacent parallel paths for combine harvesters. Biosyst. Eng. 2023, 233, 93–113. [Google Scholar] [CrossRef] [Scilit]
- Qin, D.; Leichner, C.; Delakis, M.; Fornoni, M.; Luo, S.; Yang, F.; Wang, W.; Helwegen, B.; Gunawan, R.; Howard, A. MobileNetV4: Universal models for the mobile ecosystem. arXiv 2024, arXiv:2404.10518. [Google Scholar] [CrossRef] [Scilit]
- Liu, Y.; Bai, X.; Wang, J.; Li, G.; Li, J.; Lv, Z. Image semantic segmentation approach based on DeepLabV3 plus network with an attention mechanism. Eng. Appl. Artif. Intell. 2024, 127, 107260. [Google Scholar] [CrossRef] [Scilit]
- Yu, H.; Luo, Q.; Peng, W.; Zheng, L.; Ju, J.; Zhuo, H. PKD-YOLOv8: A collaborative pruning and knowledge distillation framework for lightweight rapeseed pest detection. Sensors 2025, 25, 5004. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Yang, T.; Zhou, S.; Xu, A.; Ye, J.; Yin, J. An approach for plant leaf image segmentation based on YOLOv8 and the improved DeepLabV3+. Plants 2023, 12, 3438. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Chi, Y.; Li, L.; Wang, J.; Sun, Y. Enhanced lane detection via connectivity and boundary refinement for real-time applications. Vis. Comput. 2025, 41, 10873–10882. [Google Scholar] [CrossRef] [Scilit]
- Kervadec, H.; Bouchtiba, J.; Desrosiers, C.; Granger, E.; Dolz, J.; Ben Ayed, I. Boundary loss for highly unbalanced segmentation. Med. Image Anal. 2021, 67, 101851. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Sudre, C.H.; Li, W.; Vercauteren, T.; Ourselin, S.; Jorge Cardoso, M. Generalised dice overlap as a deep learning loss function for highly unbalanced segmentations. In Deep Learning in Medical Image Analysis and Multimodal Learning for Clinical Decision Support; Cardoso, M.J., Arbel, T., Carneiro, G., Syeda-Mahmood, T., Tavares, J.M.R.S., Moradi, M., Bradley, A., Greenspan, H., Papa, J.P., Madabhushi, A., et al., Eds.; Springer International Publishing: Cham, Switzerland, 2017; Volume 10553, pp. 240–248. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Zhao, H.; Shi, J.; Qi, X.; Wang, X.; Jia, J. Pyramid scene parsing network. In Proceedings of the 2017 IEEE Conference on Computer Vision and Pattern Recognition (CVPR), Honolulu, HI, USA, 21–26 July 2017; pp. 6230–6239. [Google Scholar] [CrossRef] [Scilit]
- Wang, J.; Sun, K.; Cheng, T.; Jiang, B.; Deng, C.; Zhao, Y.; Liu, D.; Mu, Y.; Tan, M.; Wang, X.; et al. Deep high-resolution representation learning for visual recognition. IEEE Trans. Pattern Anal. Mach. Intell. 2021, 43, 3349–3364. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Chang, Z.; Li, H.; Chen, D.; Liu, Y.; Zou, C.; Chen, J.; Han, W.; Liu, S.; Zhang, N. Crop type identification using high-resolution remote sensing images based on an improved DeepLabV3+ network. Remote Sens. 2023, 15, 5088. [Google Scholar] [CrossRef] [Scilit]
- Kim, W.-S.; Lee, D.-H.; Kim, Y.-J.; Kim, T.; Lee, W.-S.; Choi, C.-H. Stereo-vision-based crop height estimation for agricultural robots. Comput. Electron. Agric. 2021, 181, 105937. [Google Scholar] [CrossRef] [Scilit]
- Yun, C.; Kim, H.-J.; Jeon, C.-W.; Gang, M.; Lee, W.S.; Han, J.G. Stereovision-based ridge-furrow detection and tracking for auto-guided cultivator. Comput. Electron. Agric. 2021, 191, 106490. [Google Scholar] [CrossRef] [Scilit]








| Class | Number of Images | Precision (%) | Recall (%) | F1-Score (%) |
|---|---|---|---|---|
| Headland | 500 | 97.43 | 98.40 | 97.91 |
| Field | 250 | 96.73 | 94.80 | 95.76 |
| Macro Average | — | 97.08 | 96.60 | 96.83 |
| CA | SP | B&D | Headland | Field | ||||
|---|---|---|---|---|---|---|---|---|
| IoU (%) | PA (%) | Precision (%) | IoU (%) | PA (%) | Precision (%) | |||
| × | × | × | 89.06 (87.98–89.86) | 92.91 (92.30–93.54) | 95.55 (94.90–95.88) | 95.02 (94.54–95.44) | 98.05 (97.82–98.18) | 96.84 (96.55–97.19) |
| √ | × | × | 91.68 (91.31–92.69) | 96.31 (95.12–96.91) | 95.01 (93.68–96.10) | 96.13 (95.25–96.87) | 97.72 (96.98–98.32) | 98.33 (97.74–98.80) |
| × | √ | × | 91.51 (89.97–91.85) | 94.92 (93.63–96.02) | 96.44 (95.30–97.36) | 96.50 (95.67–97.20) | 98.25 (97.65–98.74) | 97.62 (96.89–98.23) |
| × | × | √ | 94.06 (92.81–95.16) | 97.49 (96.57–98.22) | 96.39 (95.25–97.34) | 97.26 (96.59–97.82) | 98.69 (98.19–99.09) | 98.09 (97.48–98.59) |
| √ | √ | √ | 94.02 (92.78–95.13) | 96.95 (95.92–97.80) | 96.89 (95.82–97.75) | 97.26 (96.60–97.83) | 98.60 (98.08–99.03) | 98.63 (98.11–99.06) |
| CA-SP- DeepLabV3+ | Headland | Field | ||||
|---|---|---|---|---|---|---|
| IoU (%) | PA (%) | Precision (%) | IoU (%) | PA (%) | Precision (%) | |
| CE Loss | 89.06 (87.98–89.86) | 92.91 (92.30–93.54) | 95.55 (94.90–95.88) | 95.02 (94.54–95.44) | 98.05 (97.82–98.18) | 96.84 (96.55–97.19) |
| Boundary Loss | 91.18 (89.70–92.48) | 95.70 (94.51–96.68) | 95.07 (93.75–96.17) | 95.91 (95.01–96.69) | 96.73 (95.85–97.48) | 97.13 (96.29–97.84) |
| Dice Loss | 88.93 (87.31–90.34) | 93.20 (91.68–94.47) | 95.10 (93.76–96.20) | 94.93 (93.91–95.81) | 97.84 (97.15–98.39) | 96.97 (96.11–97.70) |
| B&D Loss | 94.06 (92.81–95.16) | 97.49 (96.57–98.22) | 96.39 (95.25–97.34) | 97.26 (96.59–97.82) | 98.69 (98.19–99.09) | 98.09 (97.48–98.59) |
| Model | mIoU (%) | mPA (%) | Accuracy (%) | Weights (MB) | Speed (fps) |
|---|---|---|---|---|---|
| CA-SP-DeepLabV3+ | 95.64 (94.79–96.38) | 97.78 (97.20–98.25) | 98.09 (97.66–98.46) | 24.1 | 72 |
| DeepLabV3+ | 92.04 (91.74–92.34) | 95.48 (95.23–95.73) | 96.92 (96.23–97.52) | 22.4 | 87 |
| U-Net | 94.64 (93.69–95.48) | 97.02 (96.28–97.64) | 97.64 (97.09–98.12) | 94.9 | 19 |
| PSPNet | 95.43 (94.55–96.20) | 97.60 (96.98–98.12) | 97.99 (97.52–98.39) | 93.5 | 20 |
| HRNet | 96.13 (95.35–96.81) | 98.06 (97.53–98.49) | 98.30 (97.91–98.63) | 37.5 | 34 |
| Pruning | Knowledge Distillation | Headland | Field | Parameters (M) | FLOPs (G) | ||||
|---|---|---|---|---|---|---|---|---|---|
| IoU (%) | PA (%) | Precision (%) | IoU (%) | PA (%) | Precision (%) | ||||
| × | × | 94.02 (92.78–95.13) | 96.95 (95.92–97.80) | 96.89 (95.82–97.75) | 97.26 (96.60–97.83) | 98.60 (98.08–99.03) | 98.63 (98.11–99.06) | 6.25 | 26.72 |
| √ | × | 88.52 (86.72–90.05) | 93.42 (91.96–94.64) | 94.40 (92.99–95.59) | 94.70 (93.66–95.60) | 97.51 (96.76–98.13) | 97.05 (96.20–97.76) | 4.47 | 13.78 |
| √ | √ | 92.55 (91.14–93.76) | 96.85 (95.80–97.70) | 95.42 (94.17–96.45) | 96.53 (95.72–97.21) | 97.90 (97.23–98.44) | 98.57 (98.04–99.00) | 4.47 | 13.78 |
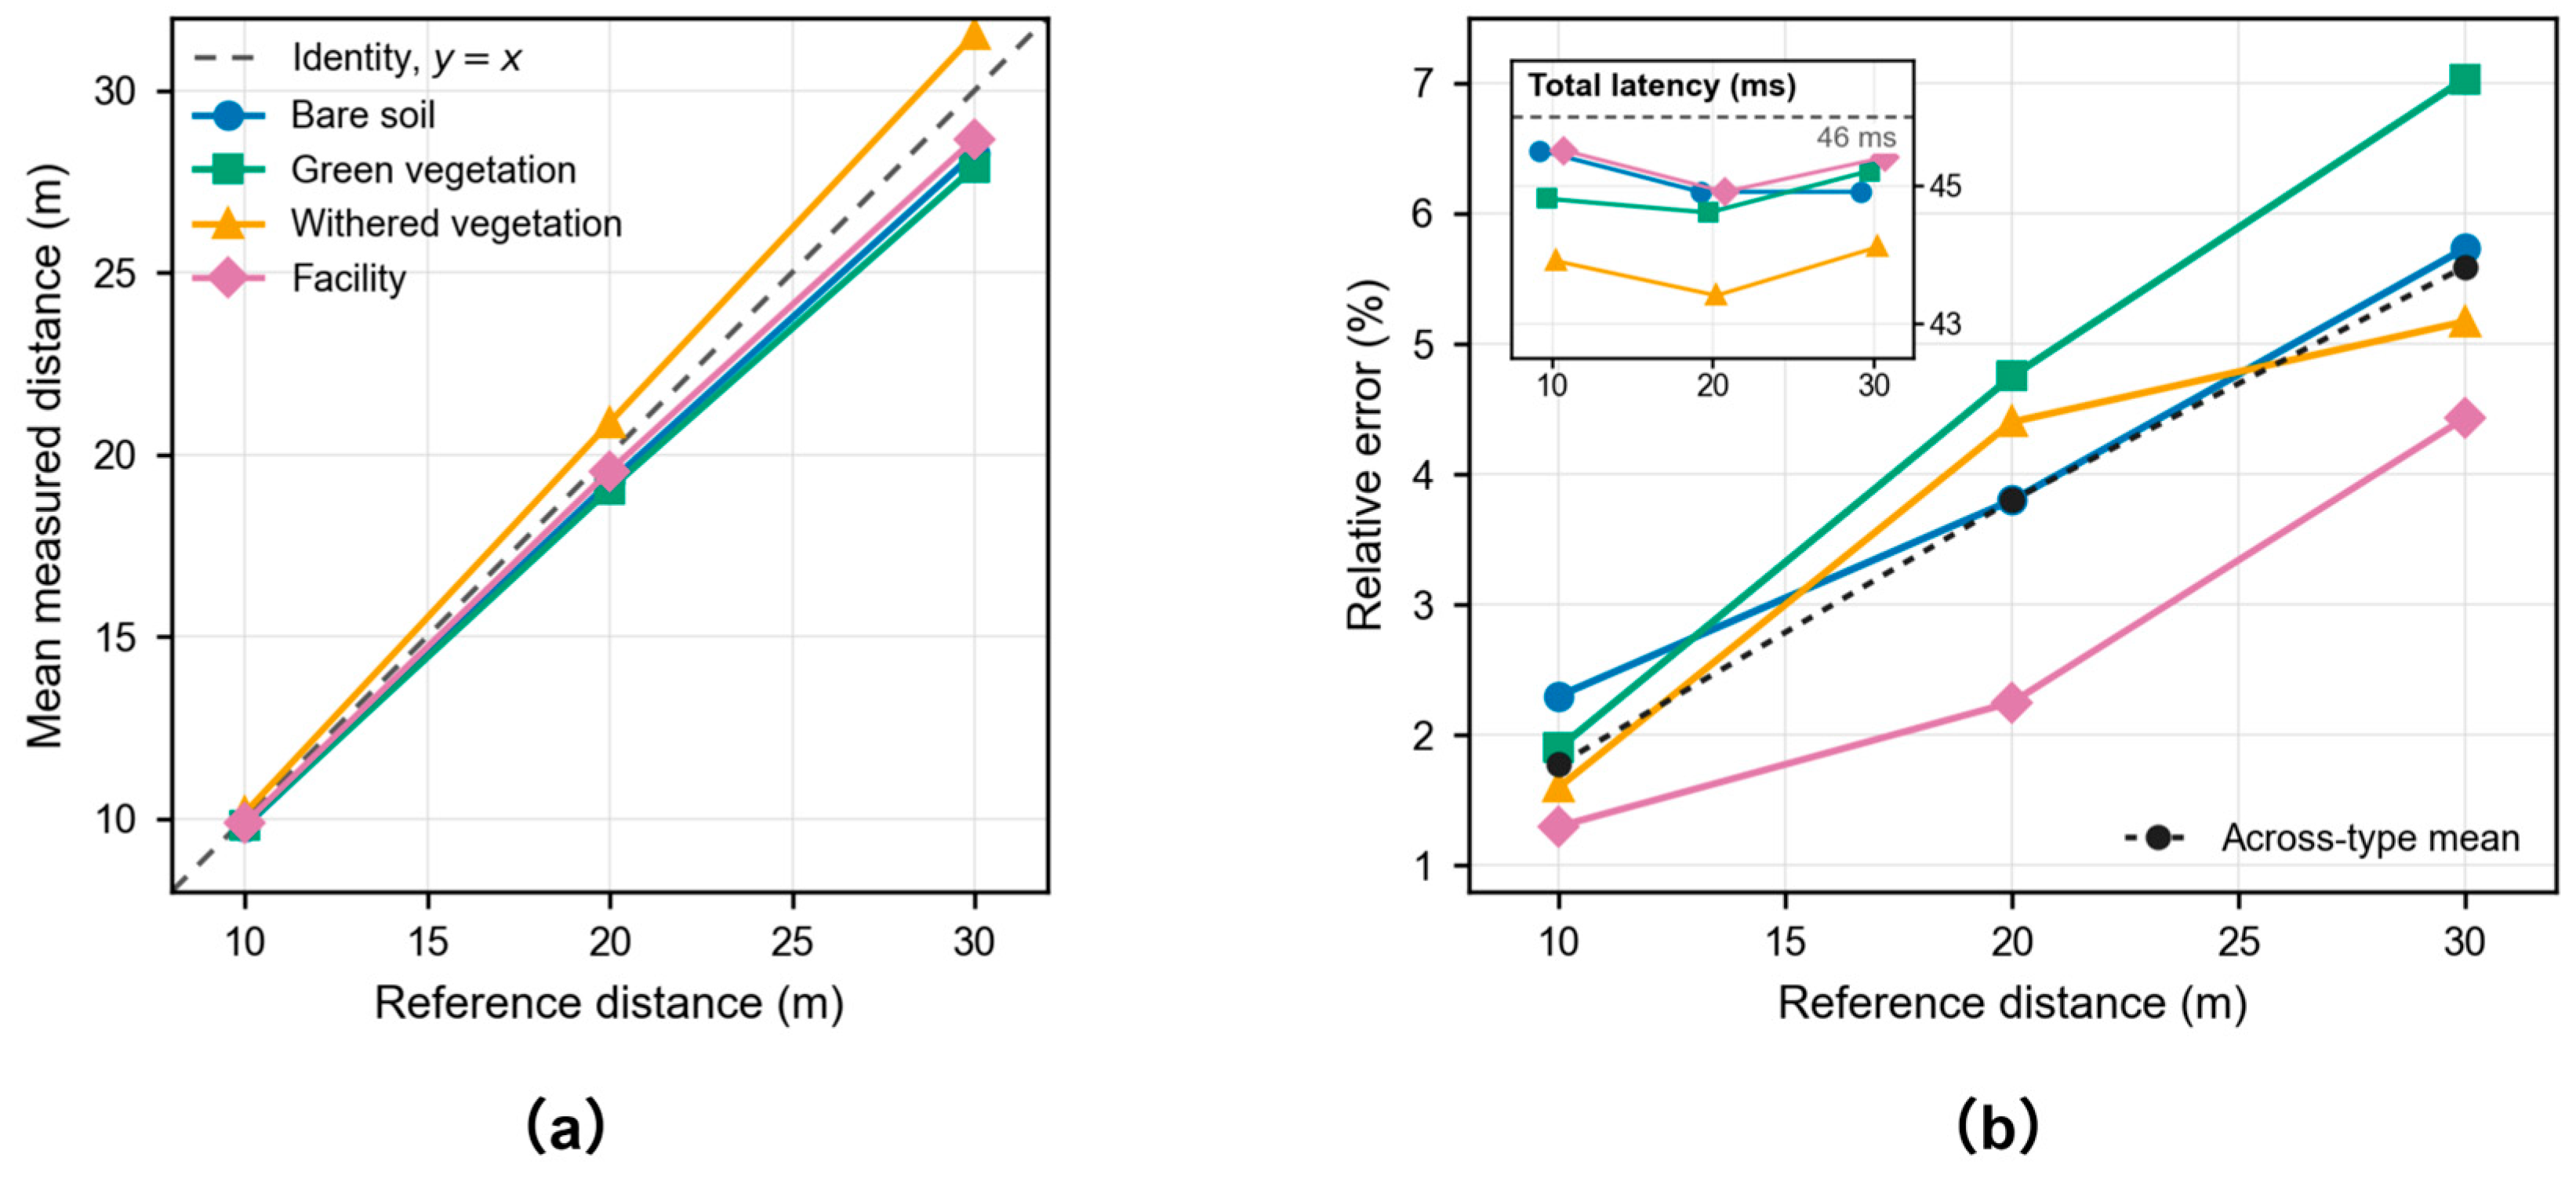
| Reference Distance | Headland Type | Measured Distance (Mean ± SD, m) | Absolute Error (m) | Relative Error (%) | Ranging Time (ms) | Inference Time (ms) |
|---|---|---|---|---|---|---|
| 30 m | Bare Soil | 28.28 ± 0.32 | 1.72 | 5.73 | 4.8 | 40.1 |
| Green Vegetation | 27.89 ± 0.45 | 2.11 | 7.03 | 5.6 | 39.6 | |
| Withered Vegetation | 31.55 ± 0.51 | 1.55 | 5.17 | 5.2 | 38.9 | |
| Artificial Facility | 28.67 ± 0.38 | 1.33 | 4.43 | 4.9 | 40.5 | |
| 20 m | Bare Soil | 19.24 ± 0.24 | 0.76 | 3.80 | 5.1 | 39.8 |
| Green Vegetation | 19.05 ± 0.31 | 0.95 | 4.75 | 5.5 | 39.1 | |
| Withered Vegetation | 20.88 ± 0.29 | 0.88 | 4.40 | 4.9 | 38.5 | |
| Artificial Facility | 19.55 ± 0.22 | 0.45 | 2.25 | 4.8 | 40.1 | |
| 10 m | Bare Soil | 9.77 ± 0.12 | 0.23 | 2.30 | 4.6 | 40.9 |
| Green Vegetation | 9.81 ± 0.15 | 0.19 | 1.90 | 5.4 | 39.4 | |
| Withered Vegetation | 10.15 ± 0.14 | 0.15 | 1.50 | 5.1 | 38.8 | |
| Artificial Facility | 9.87 ± 0.11 | 0.13 | 1.30 | 5.2 | 40.3 |
| Machine Unit Type | W (m) | e (m) | (m) | Algorithm Planning | Manual Experience | Width Reduction | ||||
|---|---|---|---|---|---|---|---|---|---|---|
| Fishtail Shape (m) | Bulb Shape (m) | Fishtail Shape (m) | Bulb Shape (m) | Fishtail Shape (%) | Bulb Shape (%) | |||||
| John Deere 1204 | Funong Seeder | 3.6 | 1.95 | 4.65 | 8.40 | 15.10 | 9.65 | 17.30 | 12.95 | 12.72 |
| Rotary Tiller | 2.45 | 1.55 | 4.65 | 7.43 | 14.63 | 8.55 | 16.85 | 13.10 | 13.18 | |
| 1590 No-Till Seeder | 4.6 | 5.75 | 8.2 | \ | 28.85 | \ | 31.50 | \ | 8.41 | |
| John Deere 904 | Funong Seeder | 3.6 | 1.9 | 3.9 | 7.60 | 12.92 | 8.70 | 14.80 | 12.64 | 12.70 |
| Rotary Tiller | 2.45 | 1.5 | 3.9 | 6.63 | 12.51 | 7.85 | 14.20 | 15.54 | 11.90 | |
| 1590 No-Till Seeder | 4.6 | 5.7 | 7.1 | \ | 25.74 | \ | 28.60 | \ | 10.00 | |
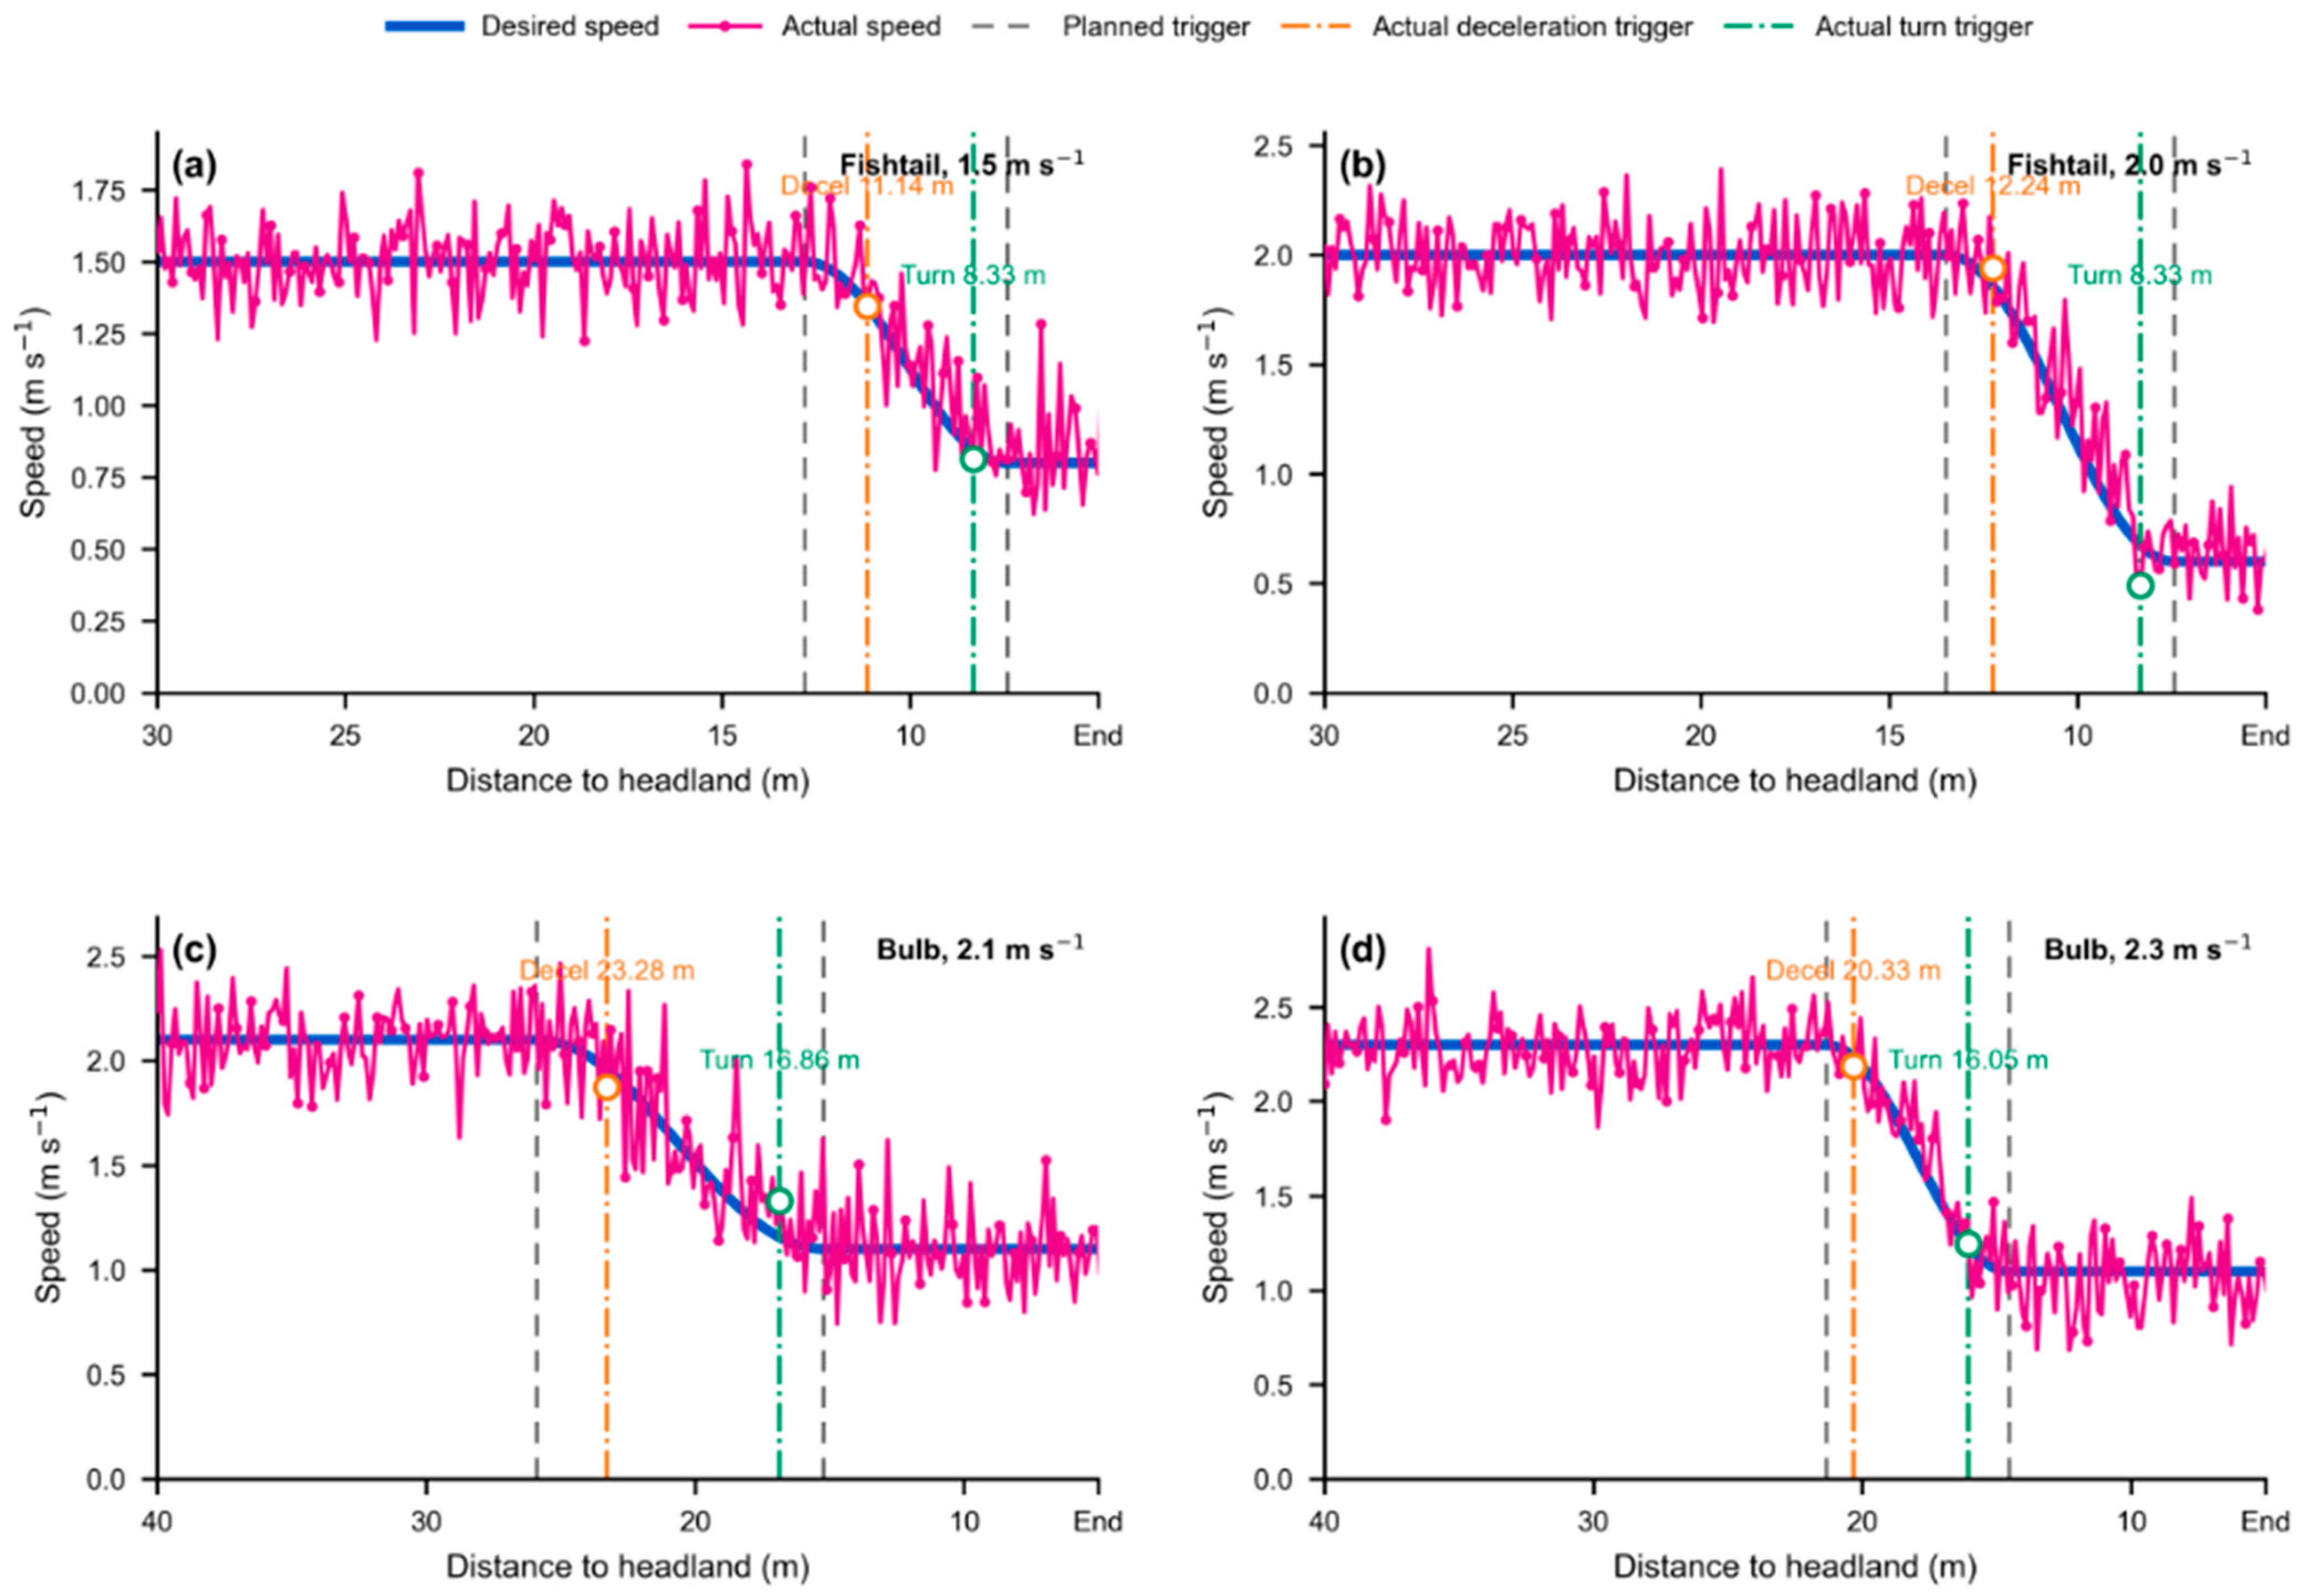
| Unit Type | Turn Type | Required Width (m) | Working Speed (m s−1) | Turning Speed (m s−1) | Deceleration (m s−2) | Deceleration Distance (m) |
|---|---|---|---|---|---|---|
| JD 1204 + Rotary Tiller | Fishtail shape | 7.43 | 1.5 | 0.8 | 0.15 | 5.37 |
| 2.0 | 0.6 | 0.30 | 6.07 | |||
| Bulb shape | 14.63 | 2.1 | 1.1 | 0.15 | 10.67 | |
| 2.3 | 1.1 | 0.30 | 6.80 |
Disclaimer/Publisher’s Note: The statements, opinions and data contained in all publications are solely those of the individual author(s) and contributor(s) and not of MDPI and/or the editor(s). MDPI and/or the editor(s) disclaim responsibility for any injury to people or property resulting from any ideas, methods, instructions or products referred to in the content. |
© 2026 by the authors. Licensee MDPI, Basel, Switzerland. This article is an open access article distributed under the terms and conditions of the Creative Commons Attribution (CC BY) license.
Share and Cite
Wang, J.; Liu, H.; Meng, Z.; Cao, X.; Zhu, X. Vision-Based Headland Boundary Perception and Decision-Making for Turn Initiation of Agricultural Machinery. Agriculture 2026, 16, 2016. https://doi.org/10.3390/agriculture16182016
Wang J, Liu H, Meng Z, Cao X, Zhu X. Vision-Based Headland Boundary Perception and Decision-Making for Turn Initiation of Agricultural Machinery. Agriculture. 2026; 16(18):2016. https://doi.org/10.3390/agriculture16182016
Chicago/Turabian StyleWang, Jinghao, Hui Liu, Zhijun Meng, Xiangchen Cao, and Xiaoyu Zhu. 2026. "Vision-Based Headland Boundary Perception and Decision-Making for Turn Initiation of Agricultural Machinery" Agriculture 16, no. 18: 2016. https://doi.org/10.3390/agriculture16182016
APA StyleWang, J., Liu, H., Meng, Z., Cao, X., & Zhu, X. (2026). Vision-Based Headland Boundary Perception and Decision-Making for Turn Initiation of Agricultural Machinery. Agriculture, 16(18), 2016. https://doi.org/10.3390/agriculture16182016