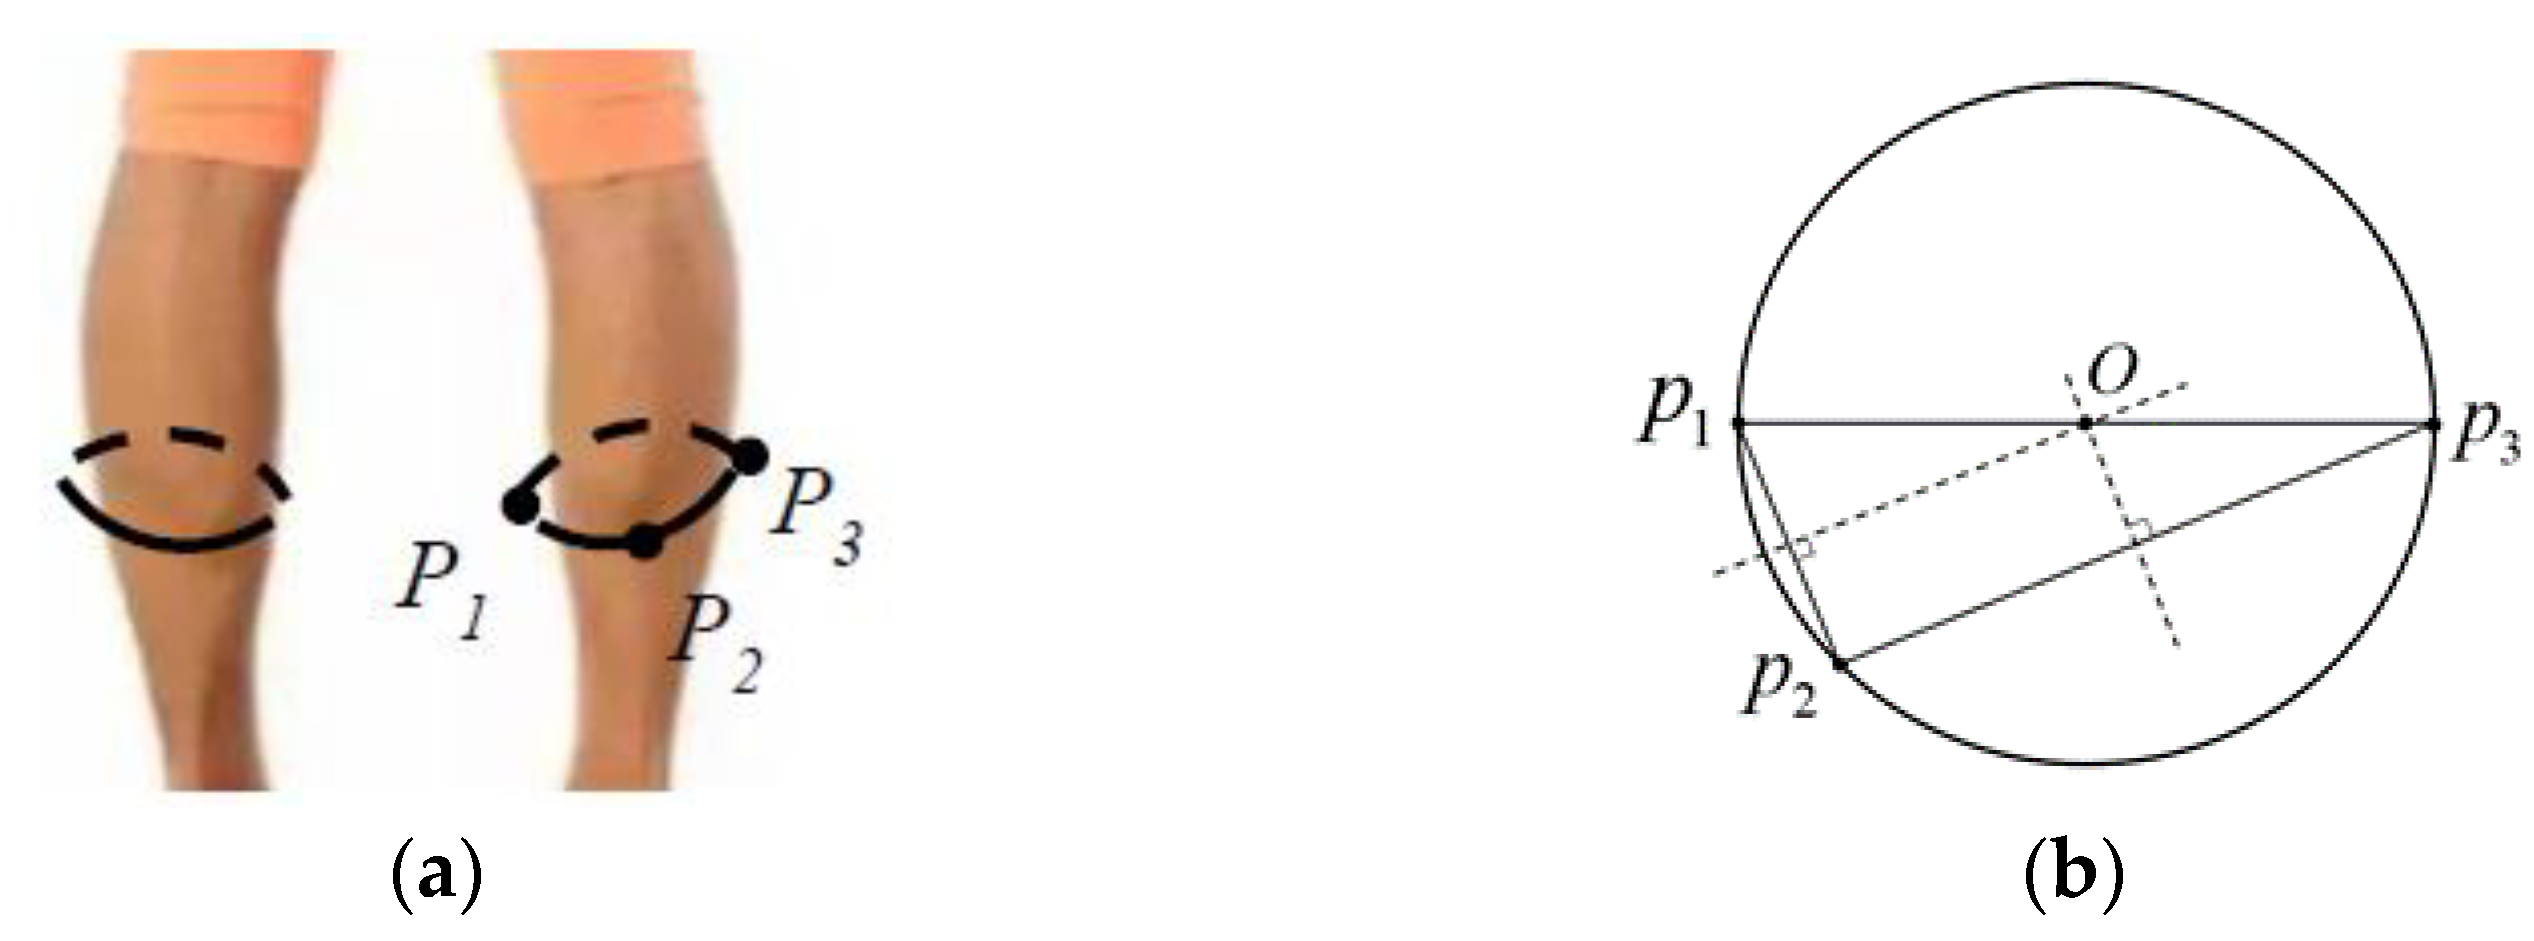Article

A Novel Auxiliary Excretion Approach to a Lavatory Robot with Safety and Robustness
1
School of Electrical Engineering, Shenyang University of Technology, Shenyang 110020, China
2
Department of Intelligent Mechanical Systems Engineering, Kochi University of Engineering, Kochi 7828502, Japan
3
Department of Mechanical Engineering and Intelligent Systems, University of Electro-Communications, Tokyo 182-8585, Japan
*
Author to whom correspondence should be addressed.
Machines 2022, 10(8), 657; https://doi.org/10.3390/machines10080657

Submission received: 5 July 2022 / Revised: 29 July 2022 / Accepted: 31 July 2022 / Published: 5 August 2022
(This article belongs to the Special Issue Intelligent Mechatronics: Perception, Optimization, and Control)

Abstract

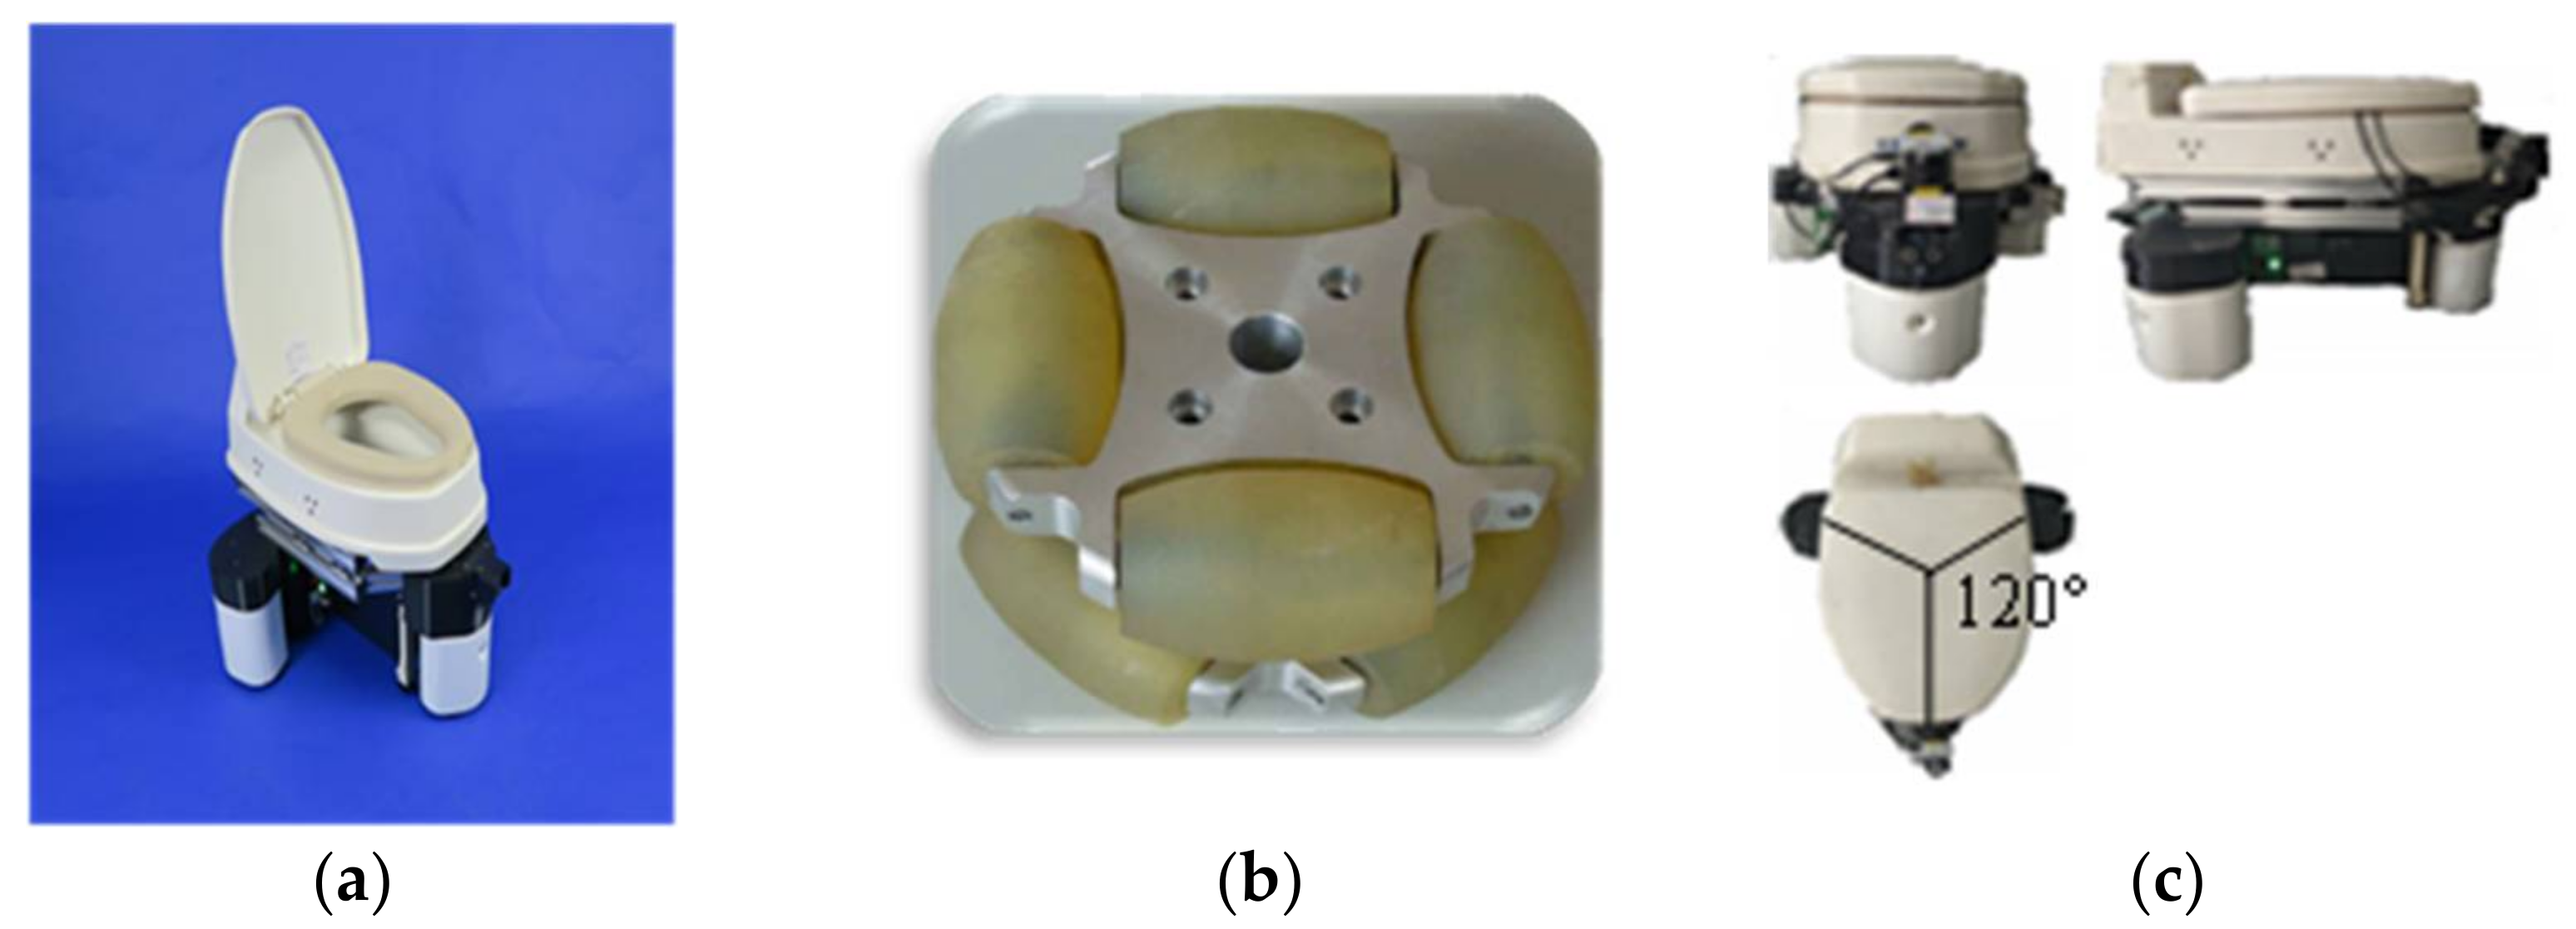
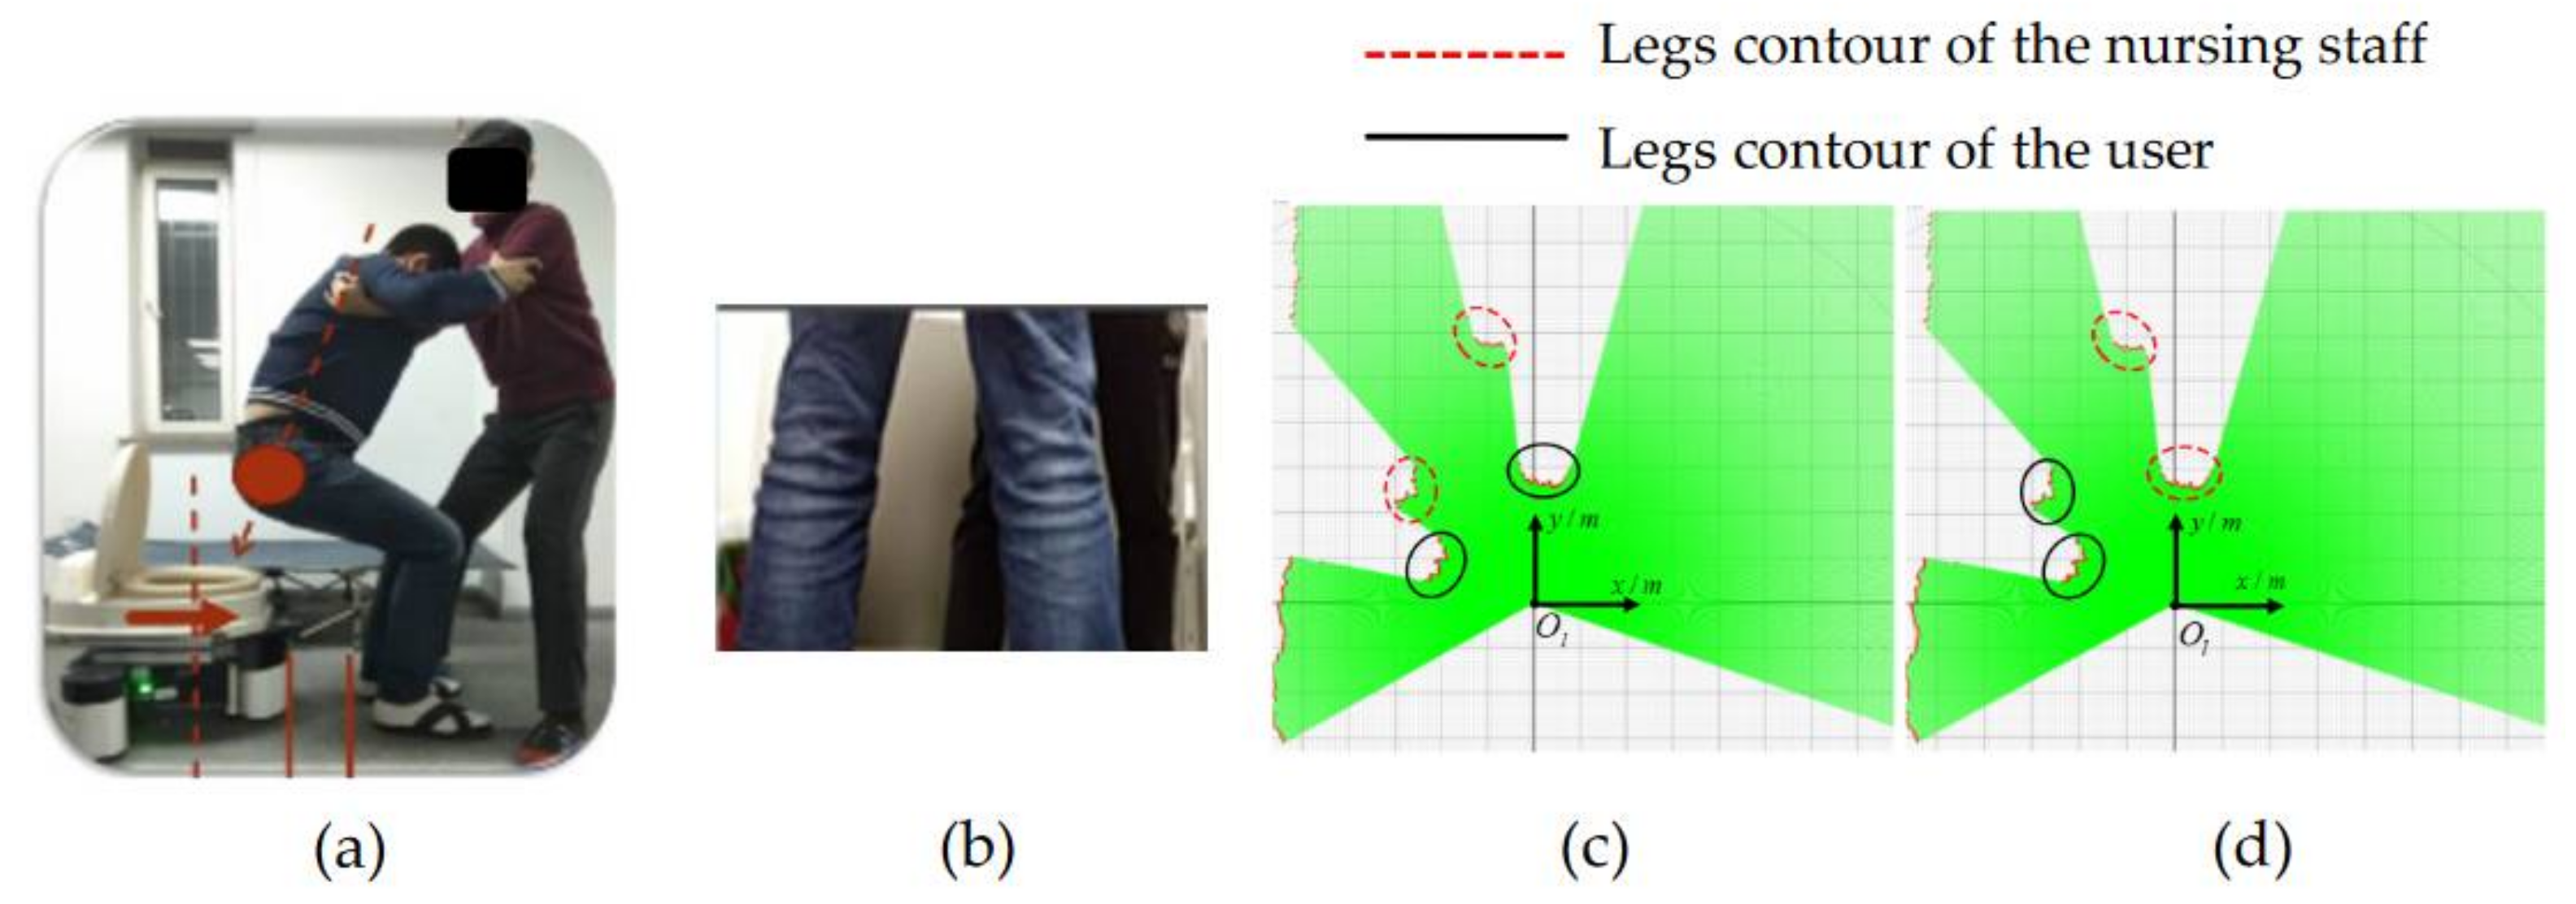
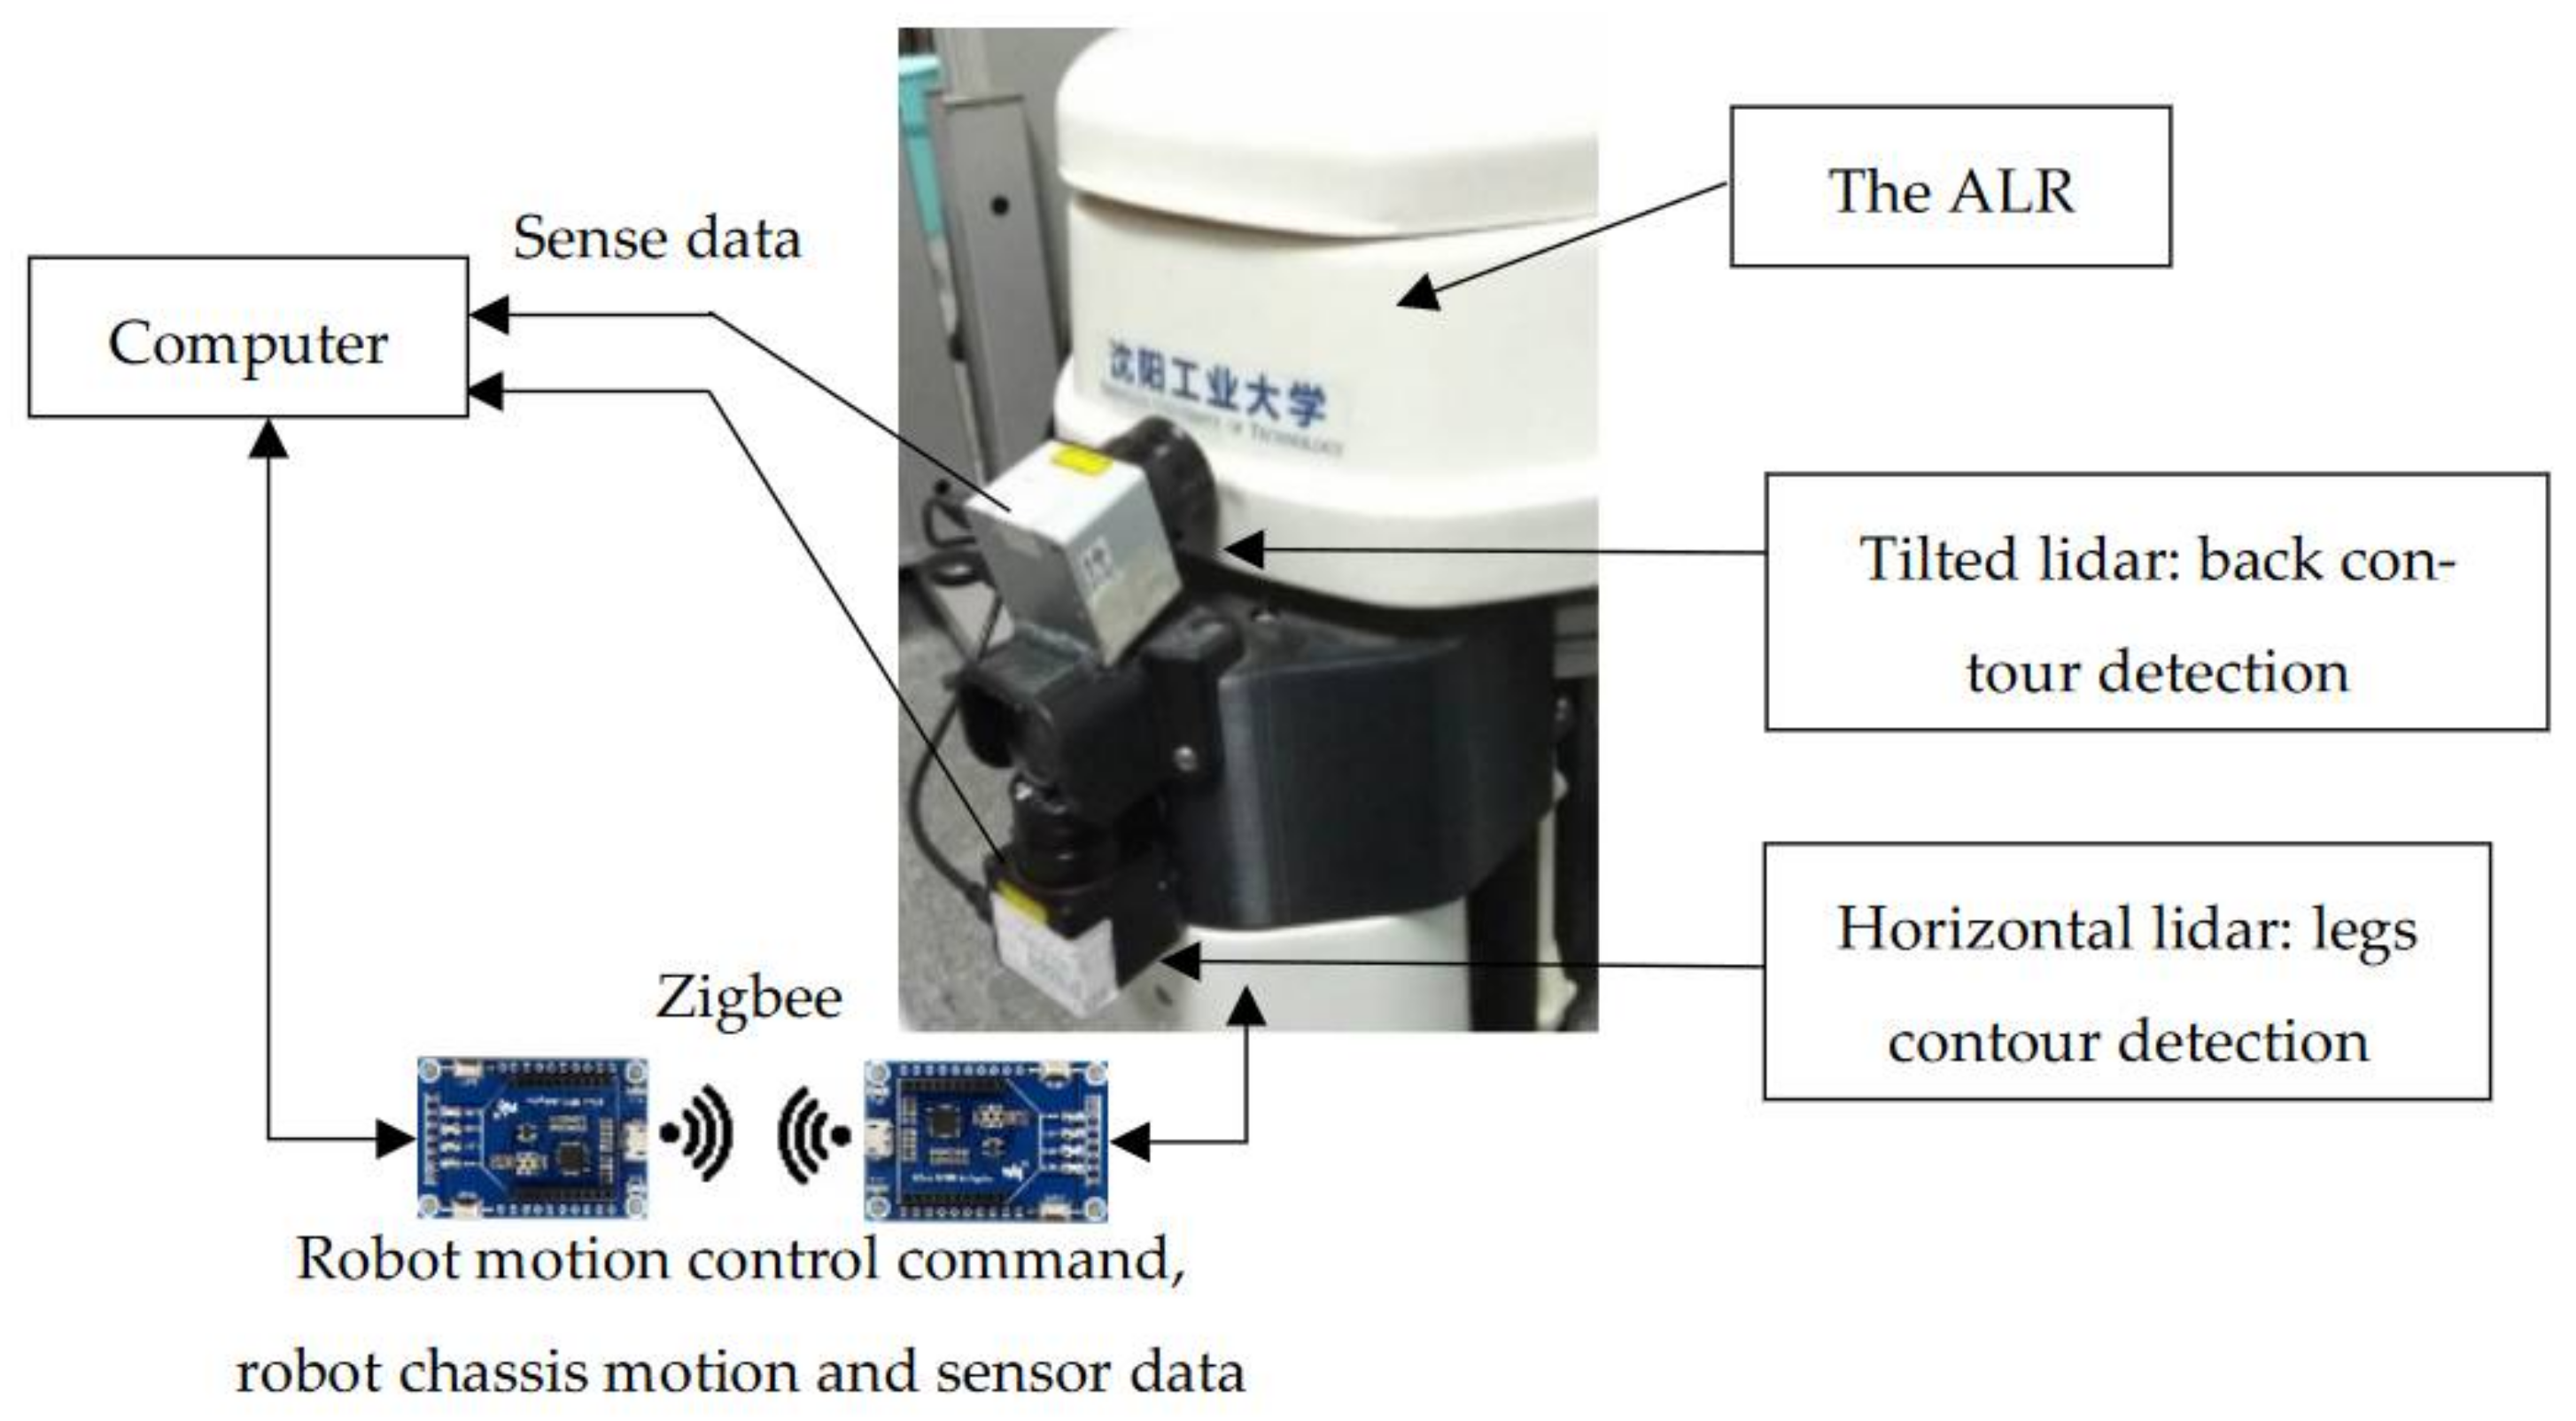
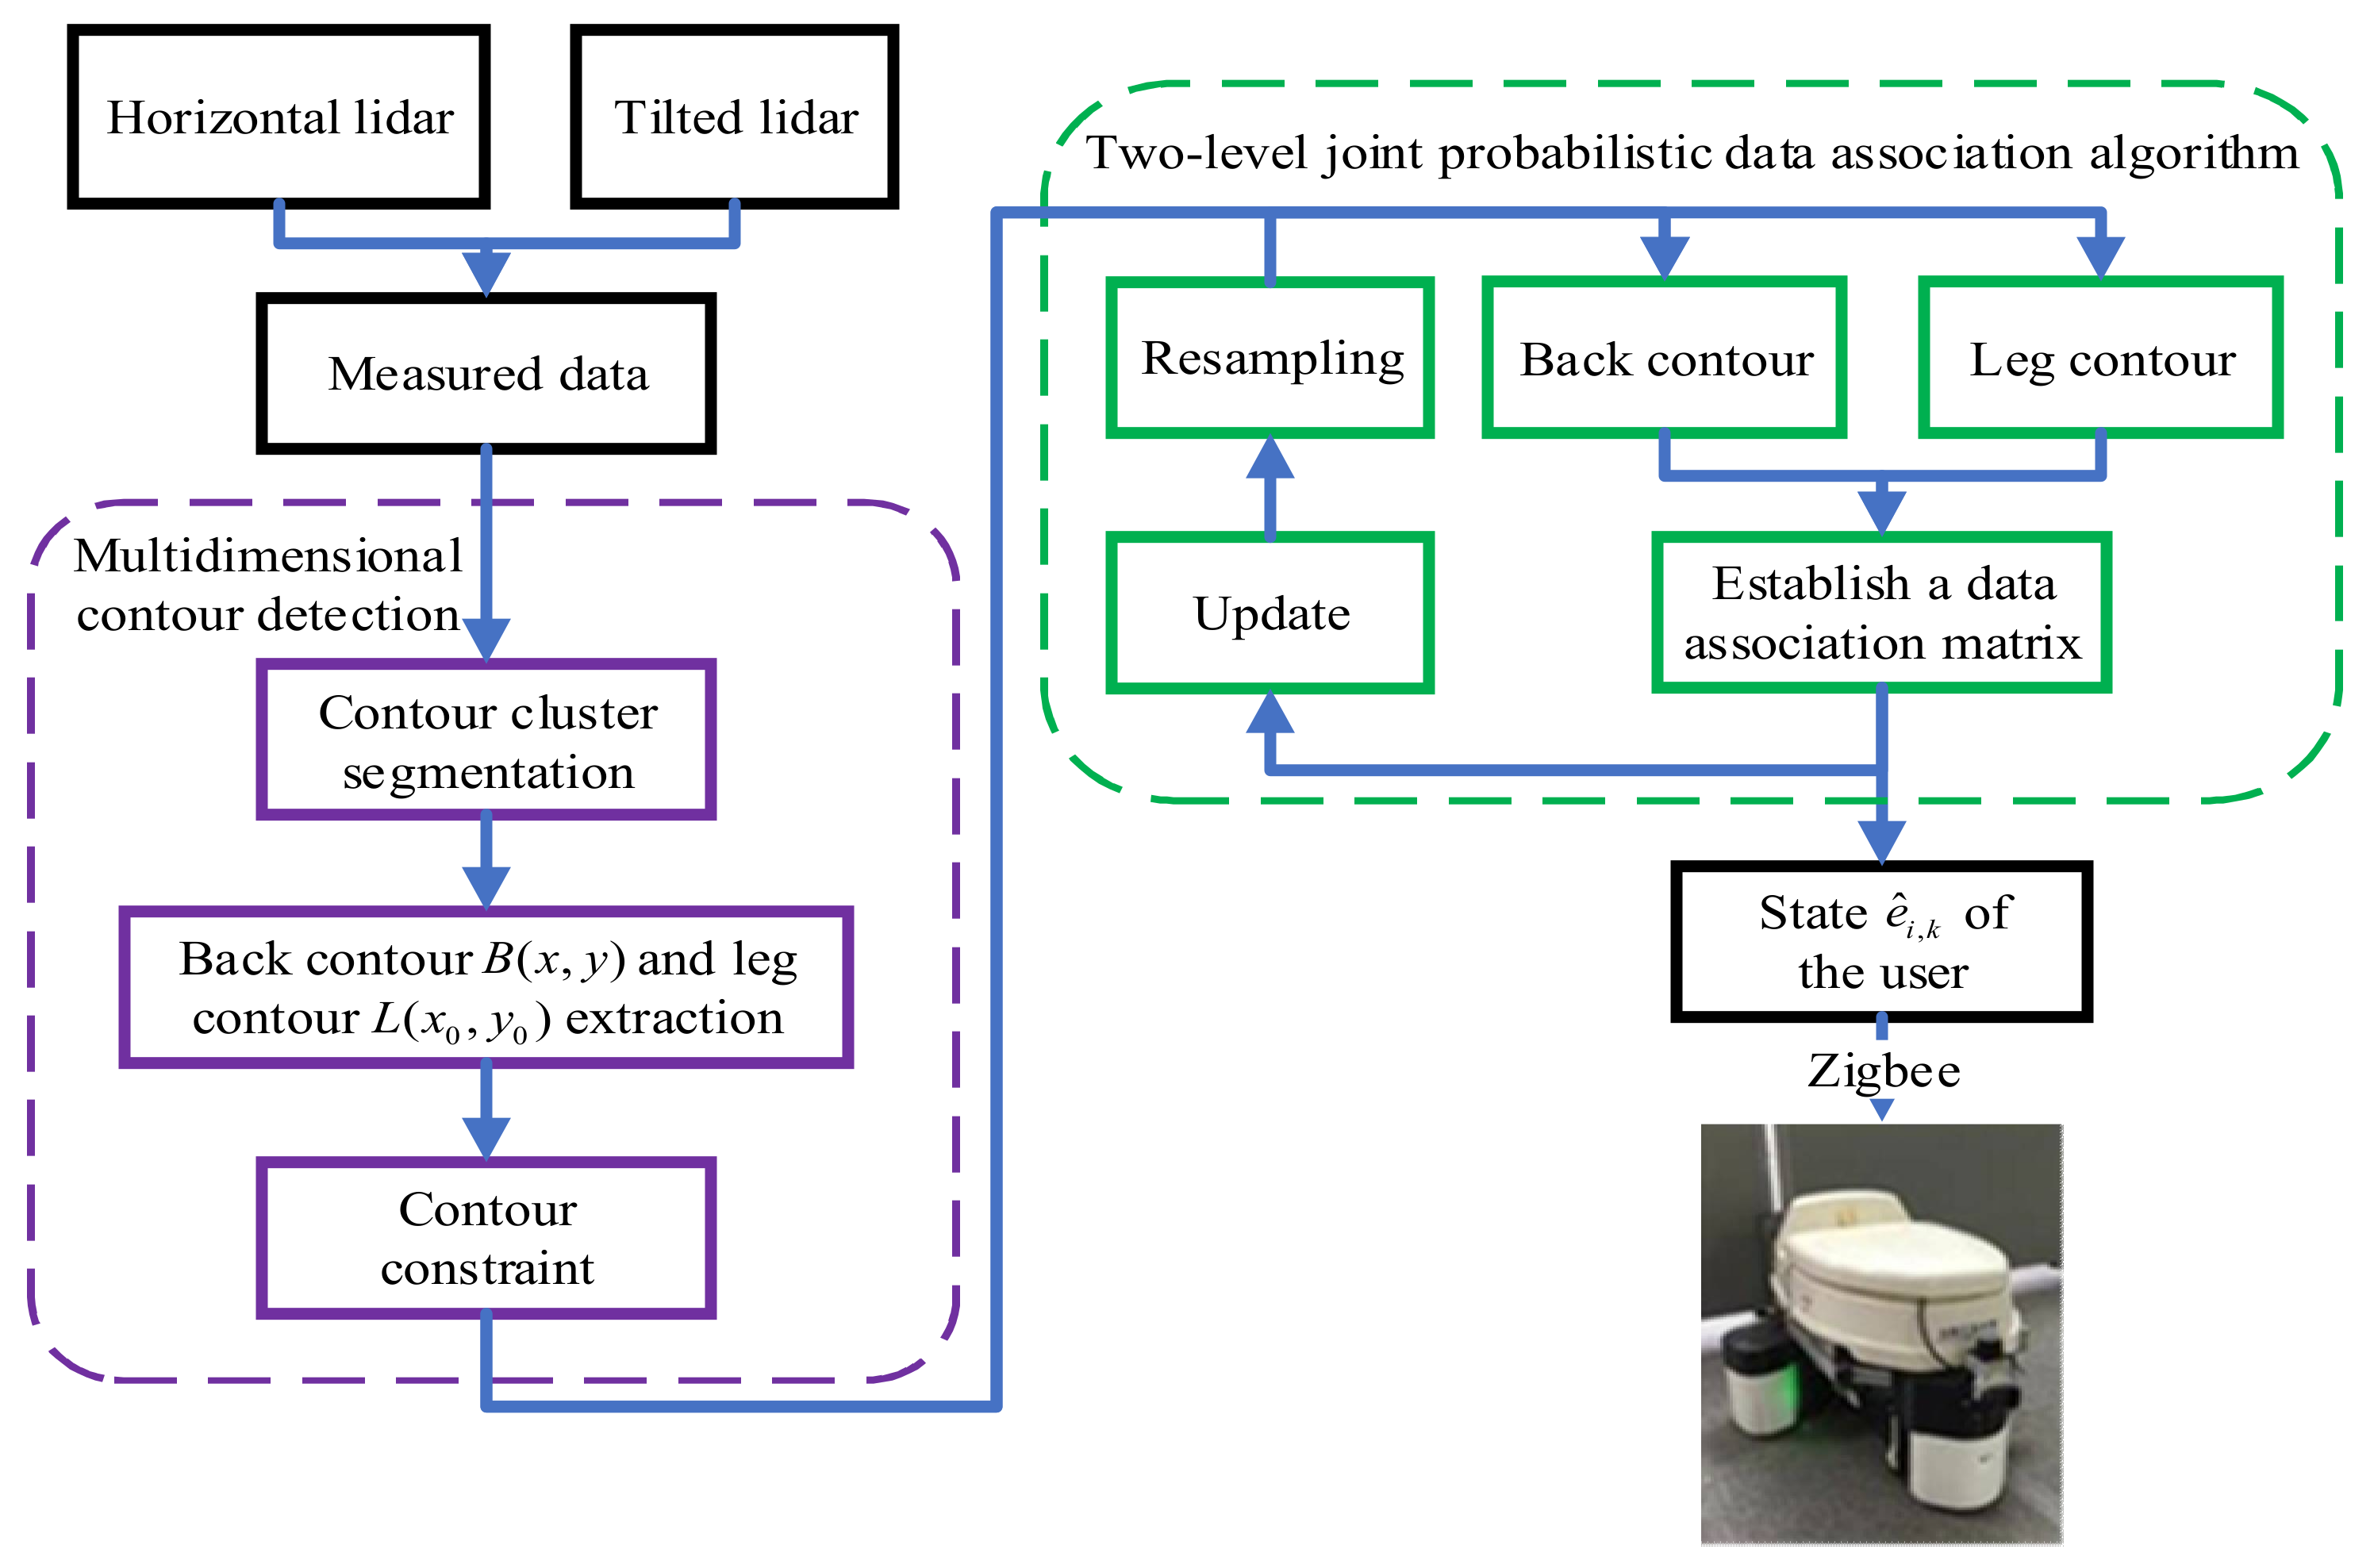
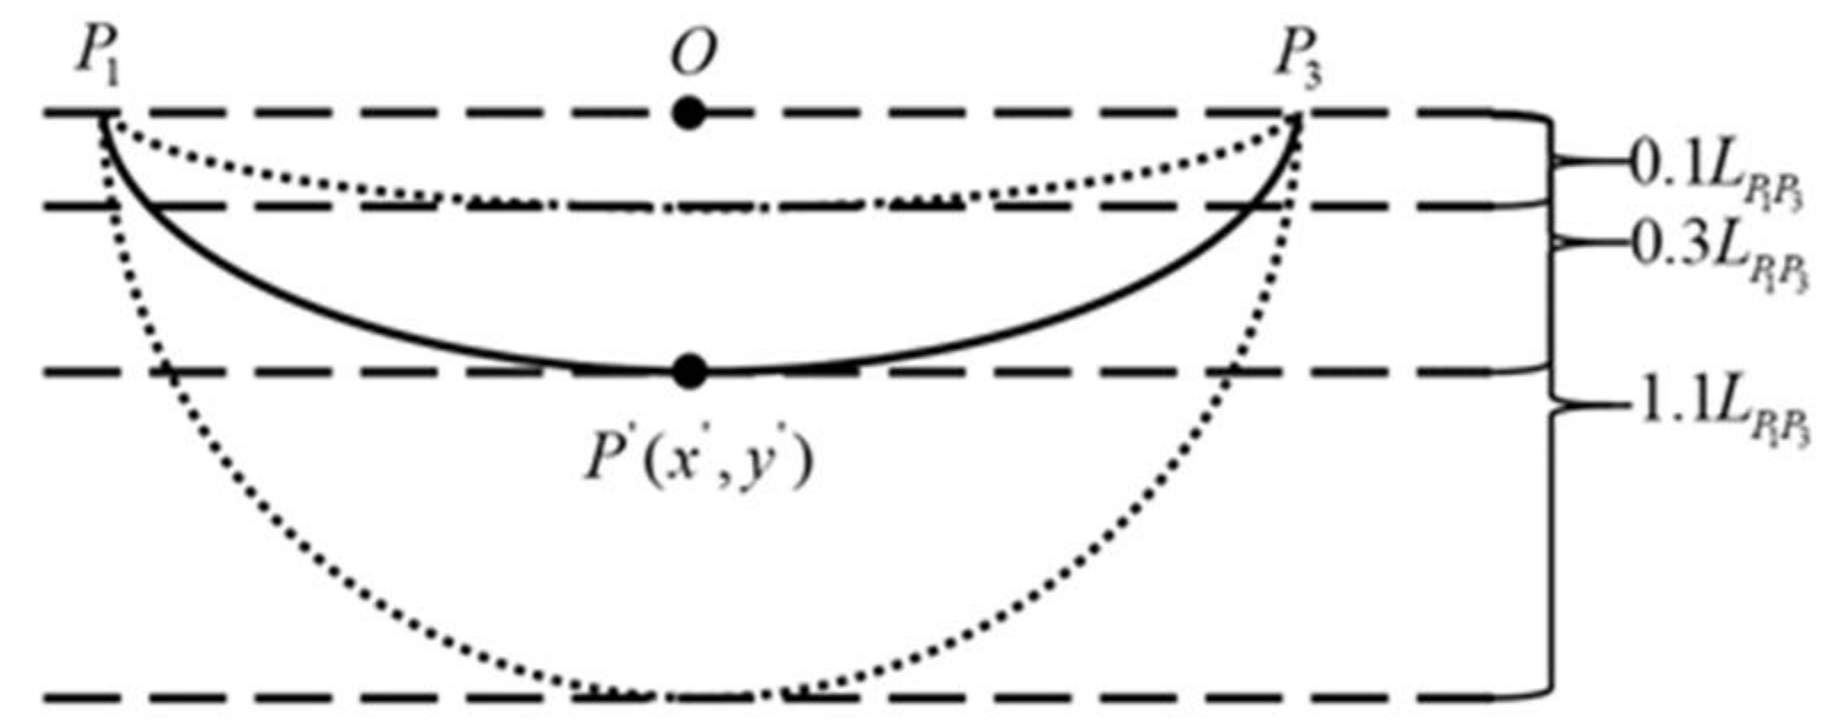
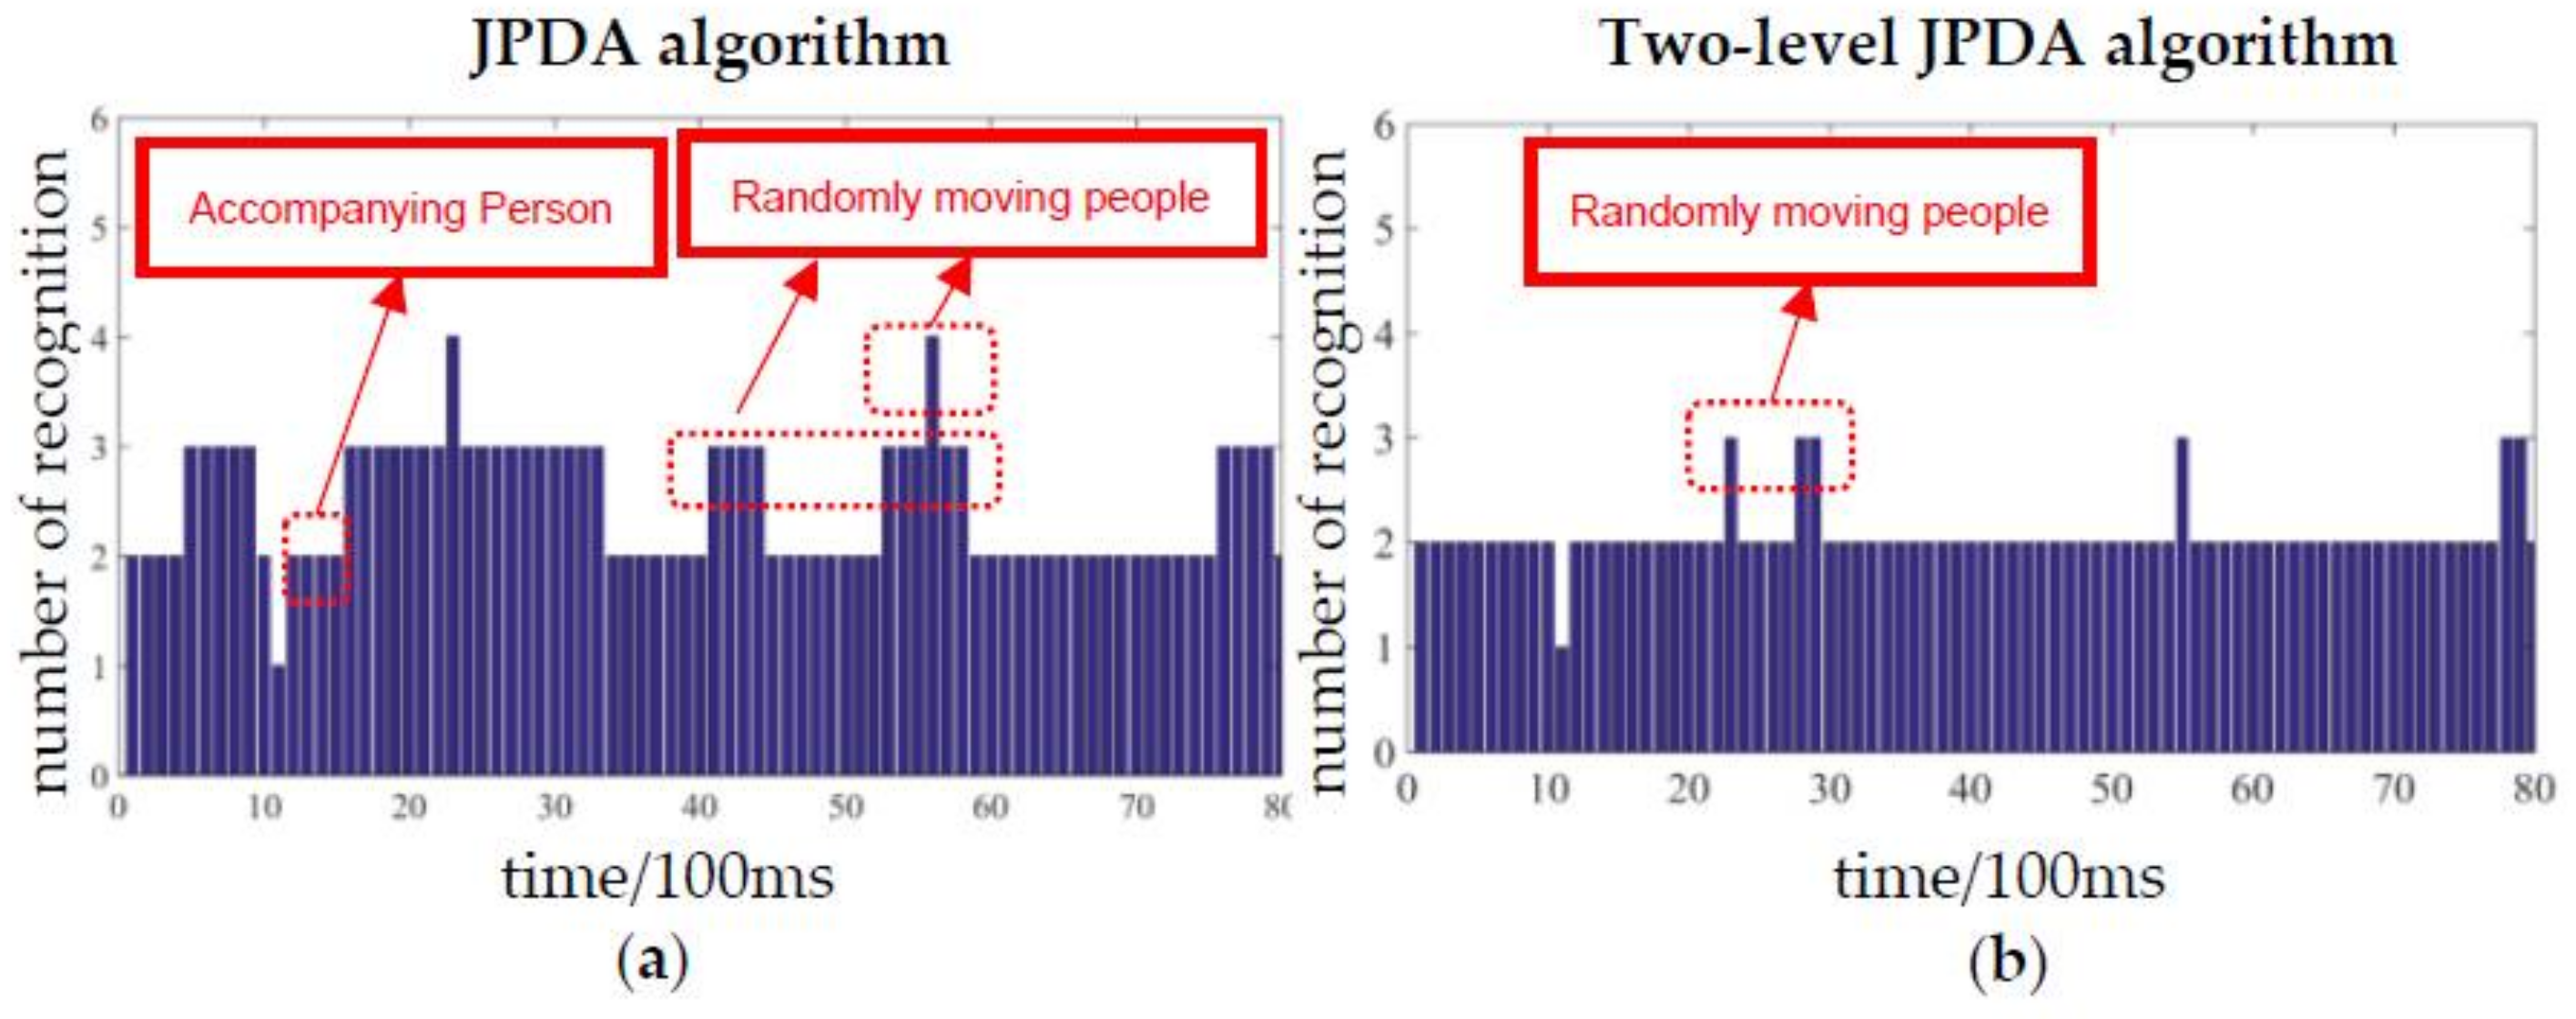
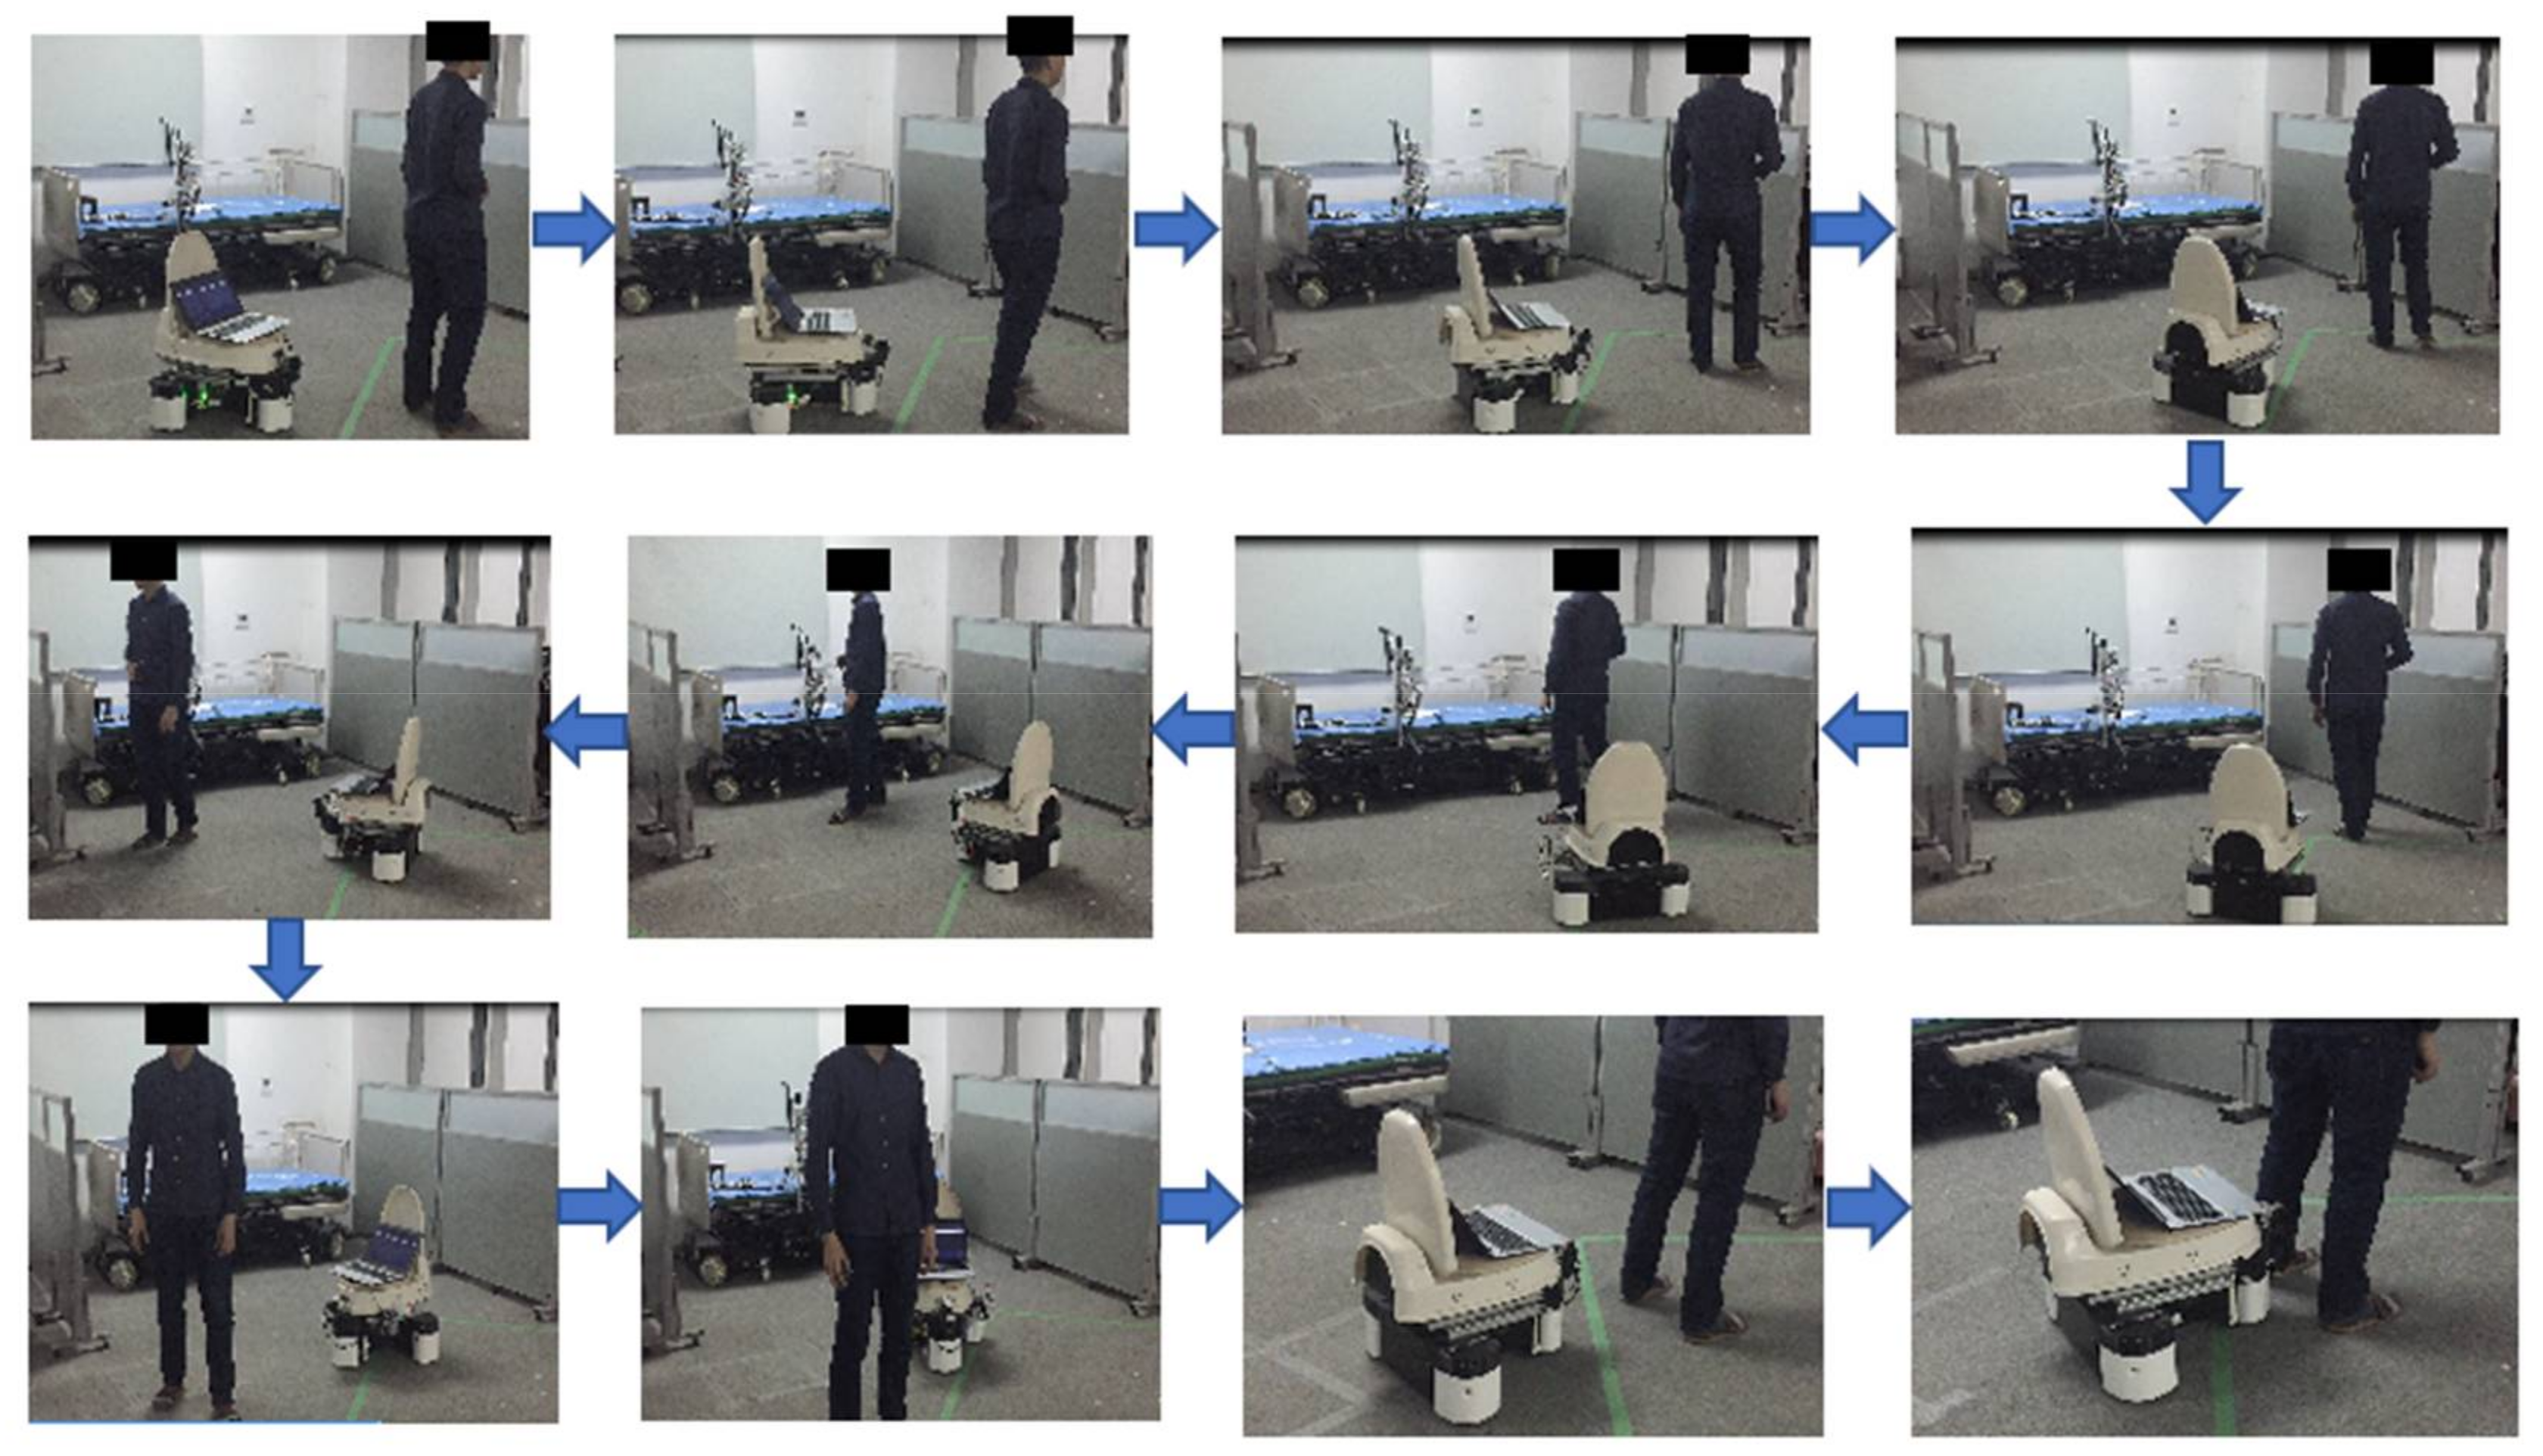
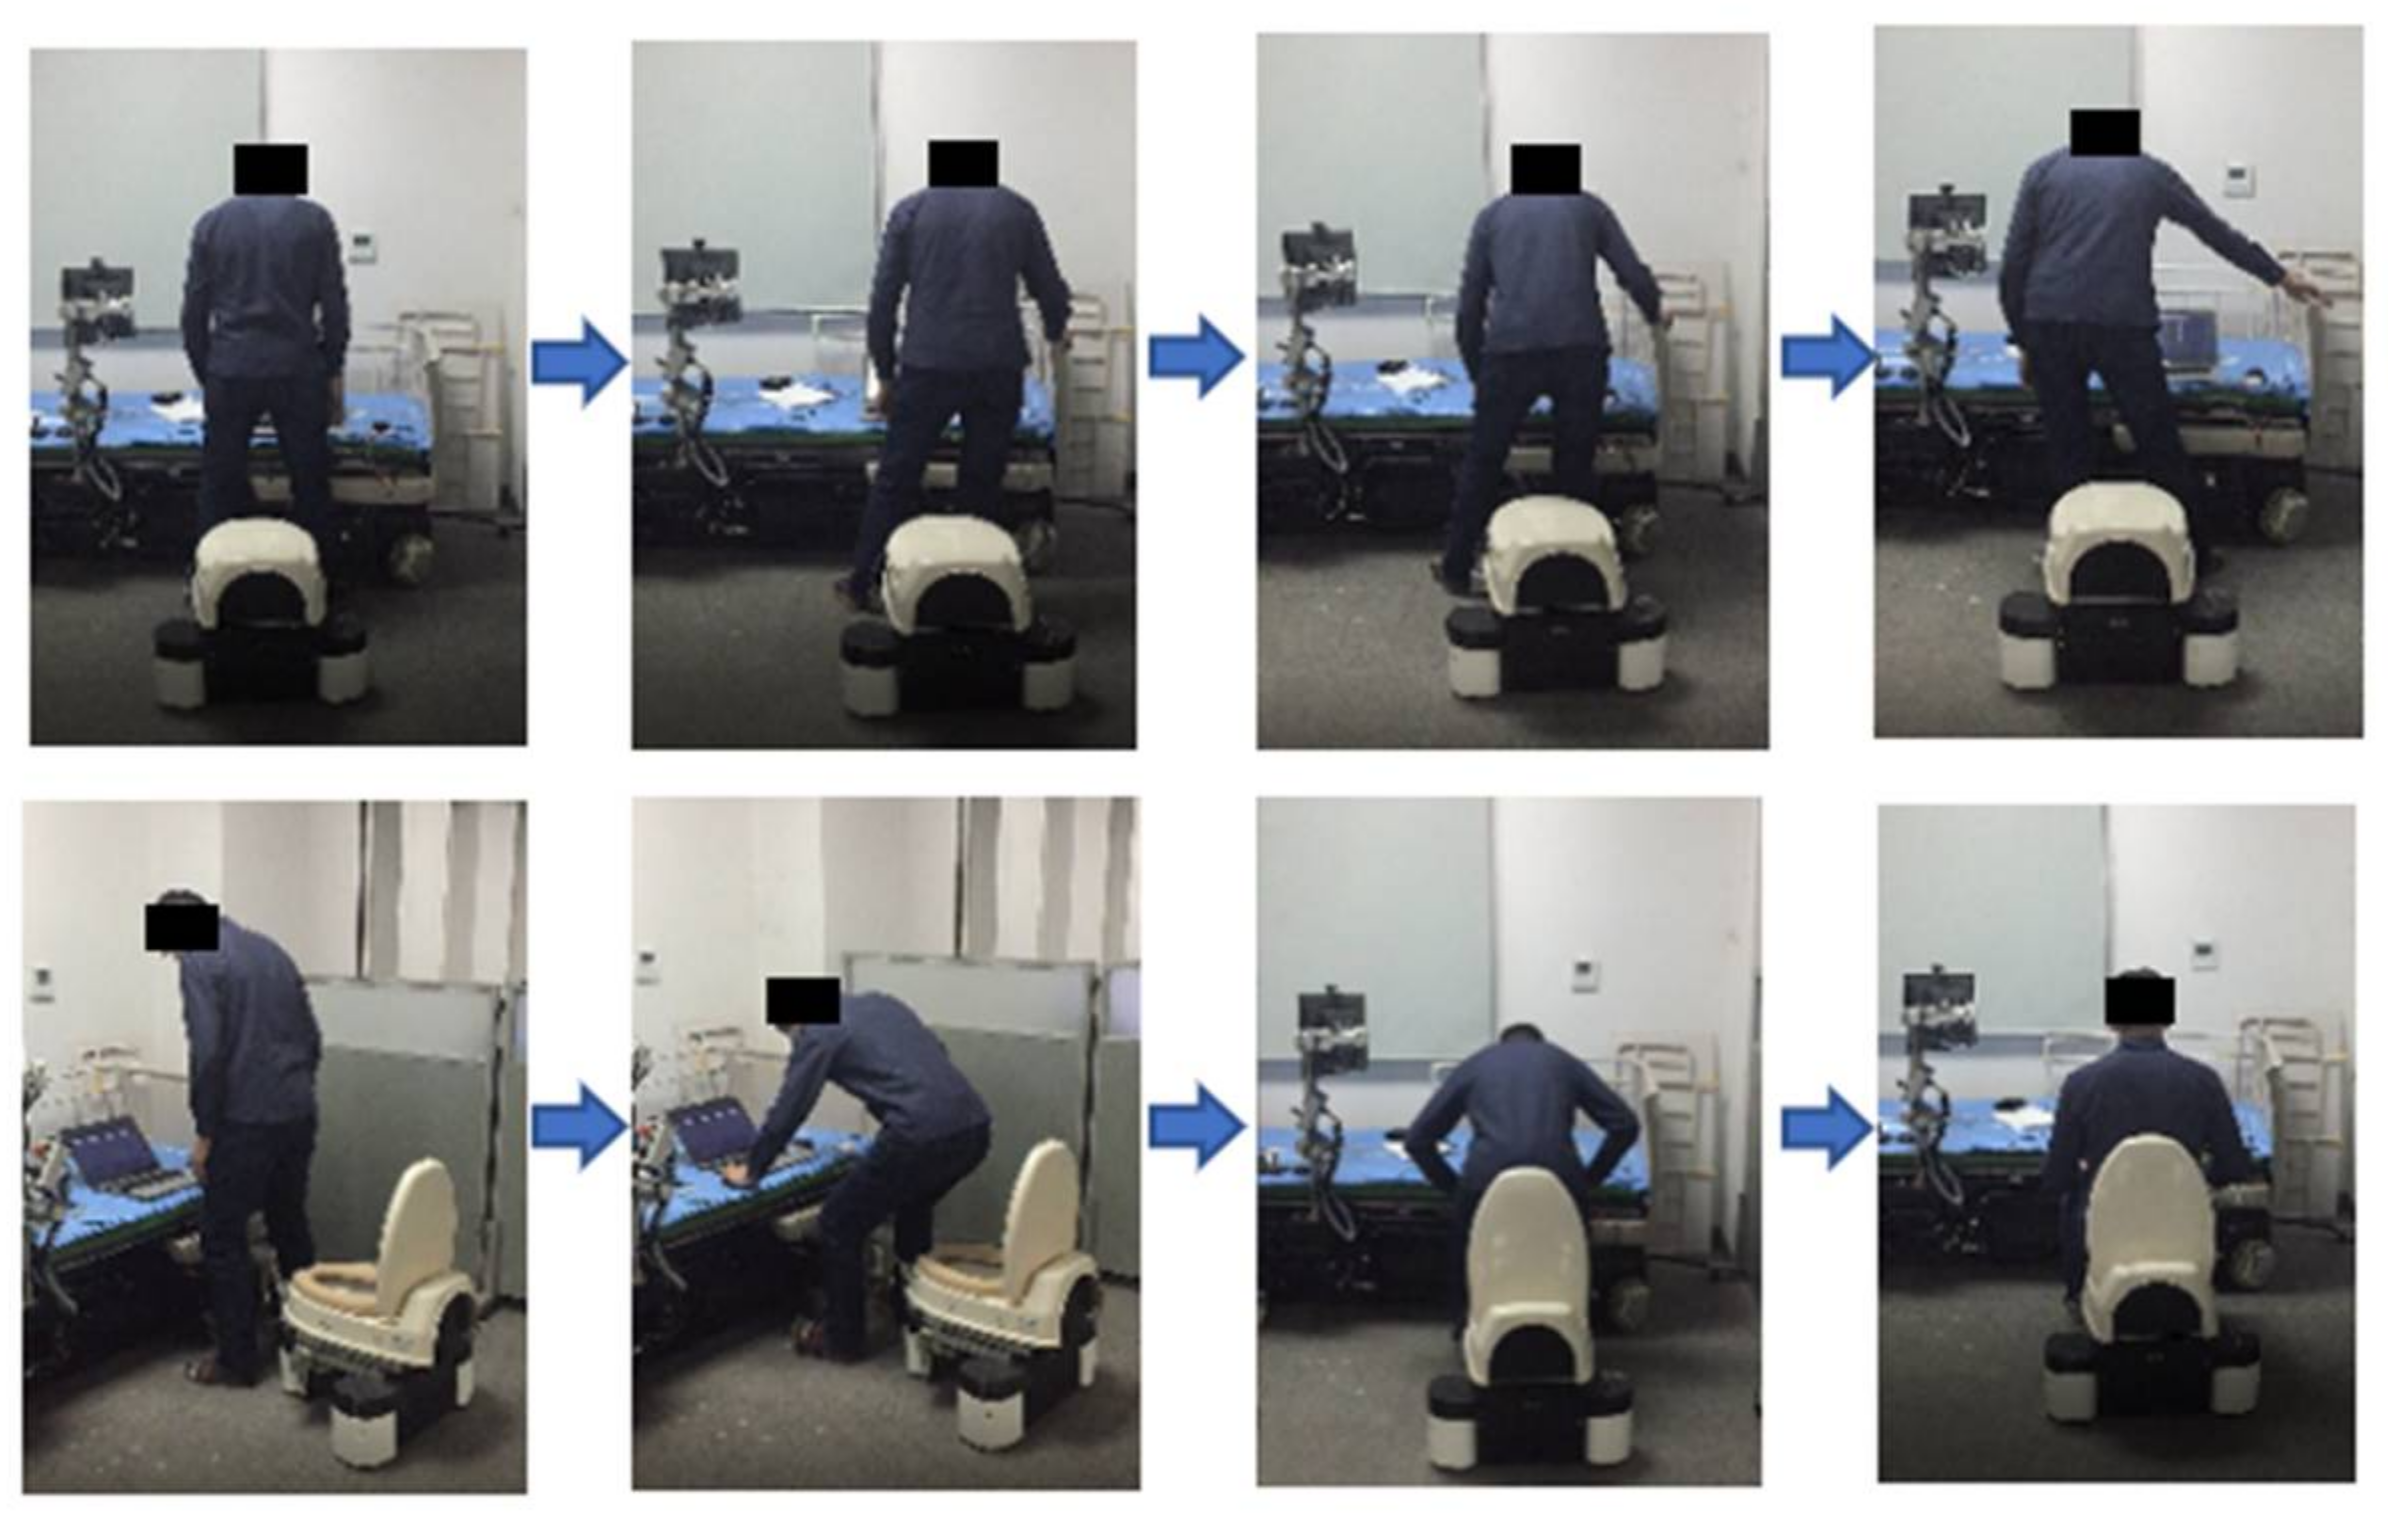
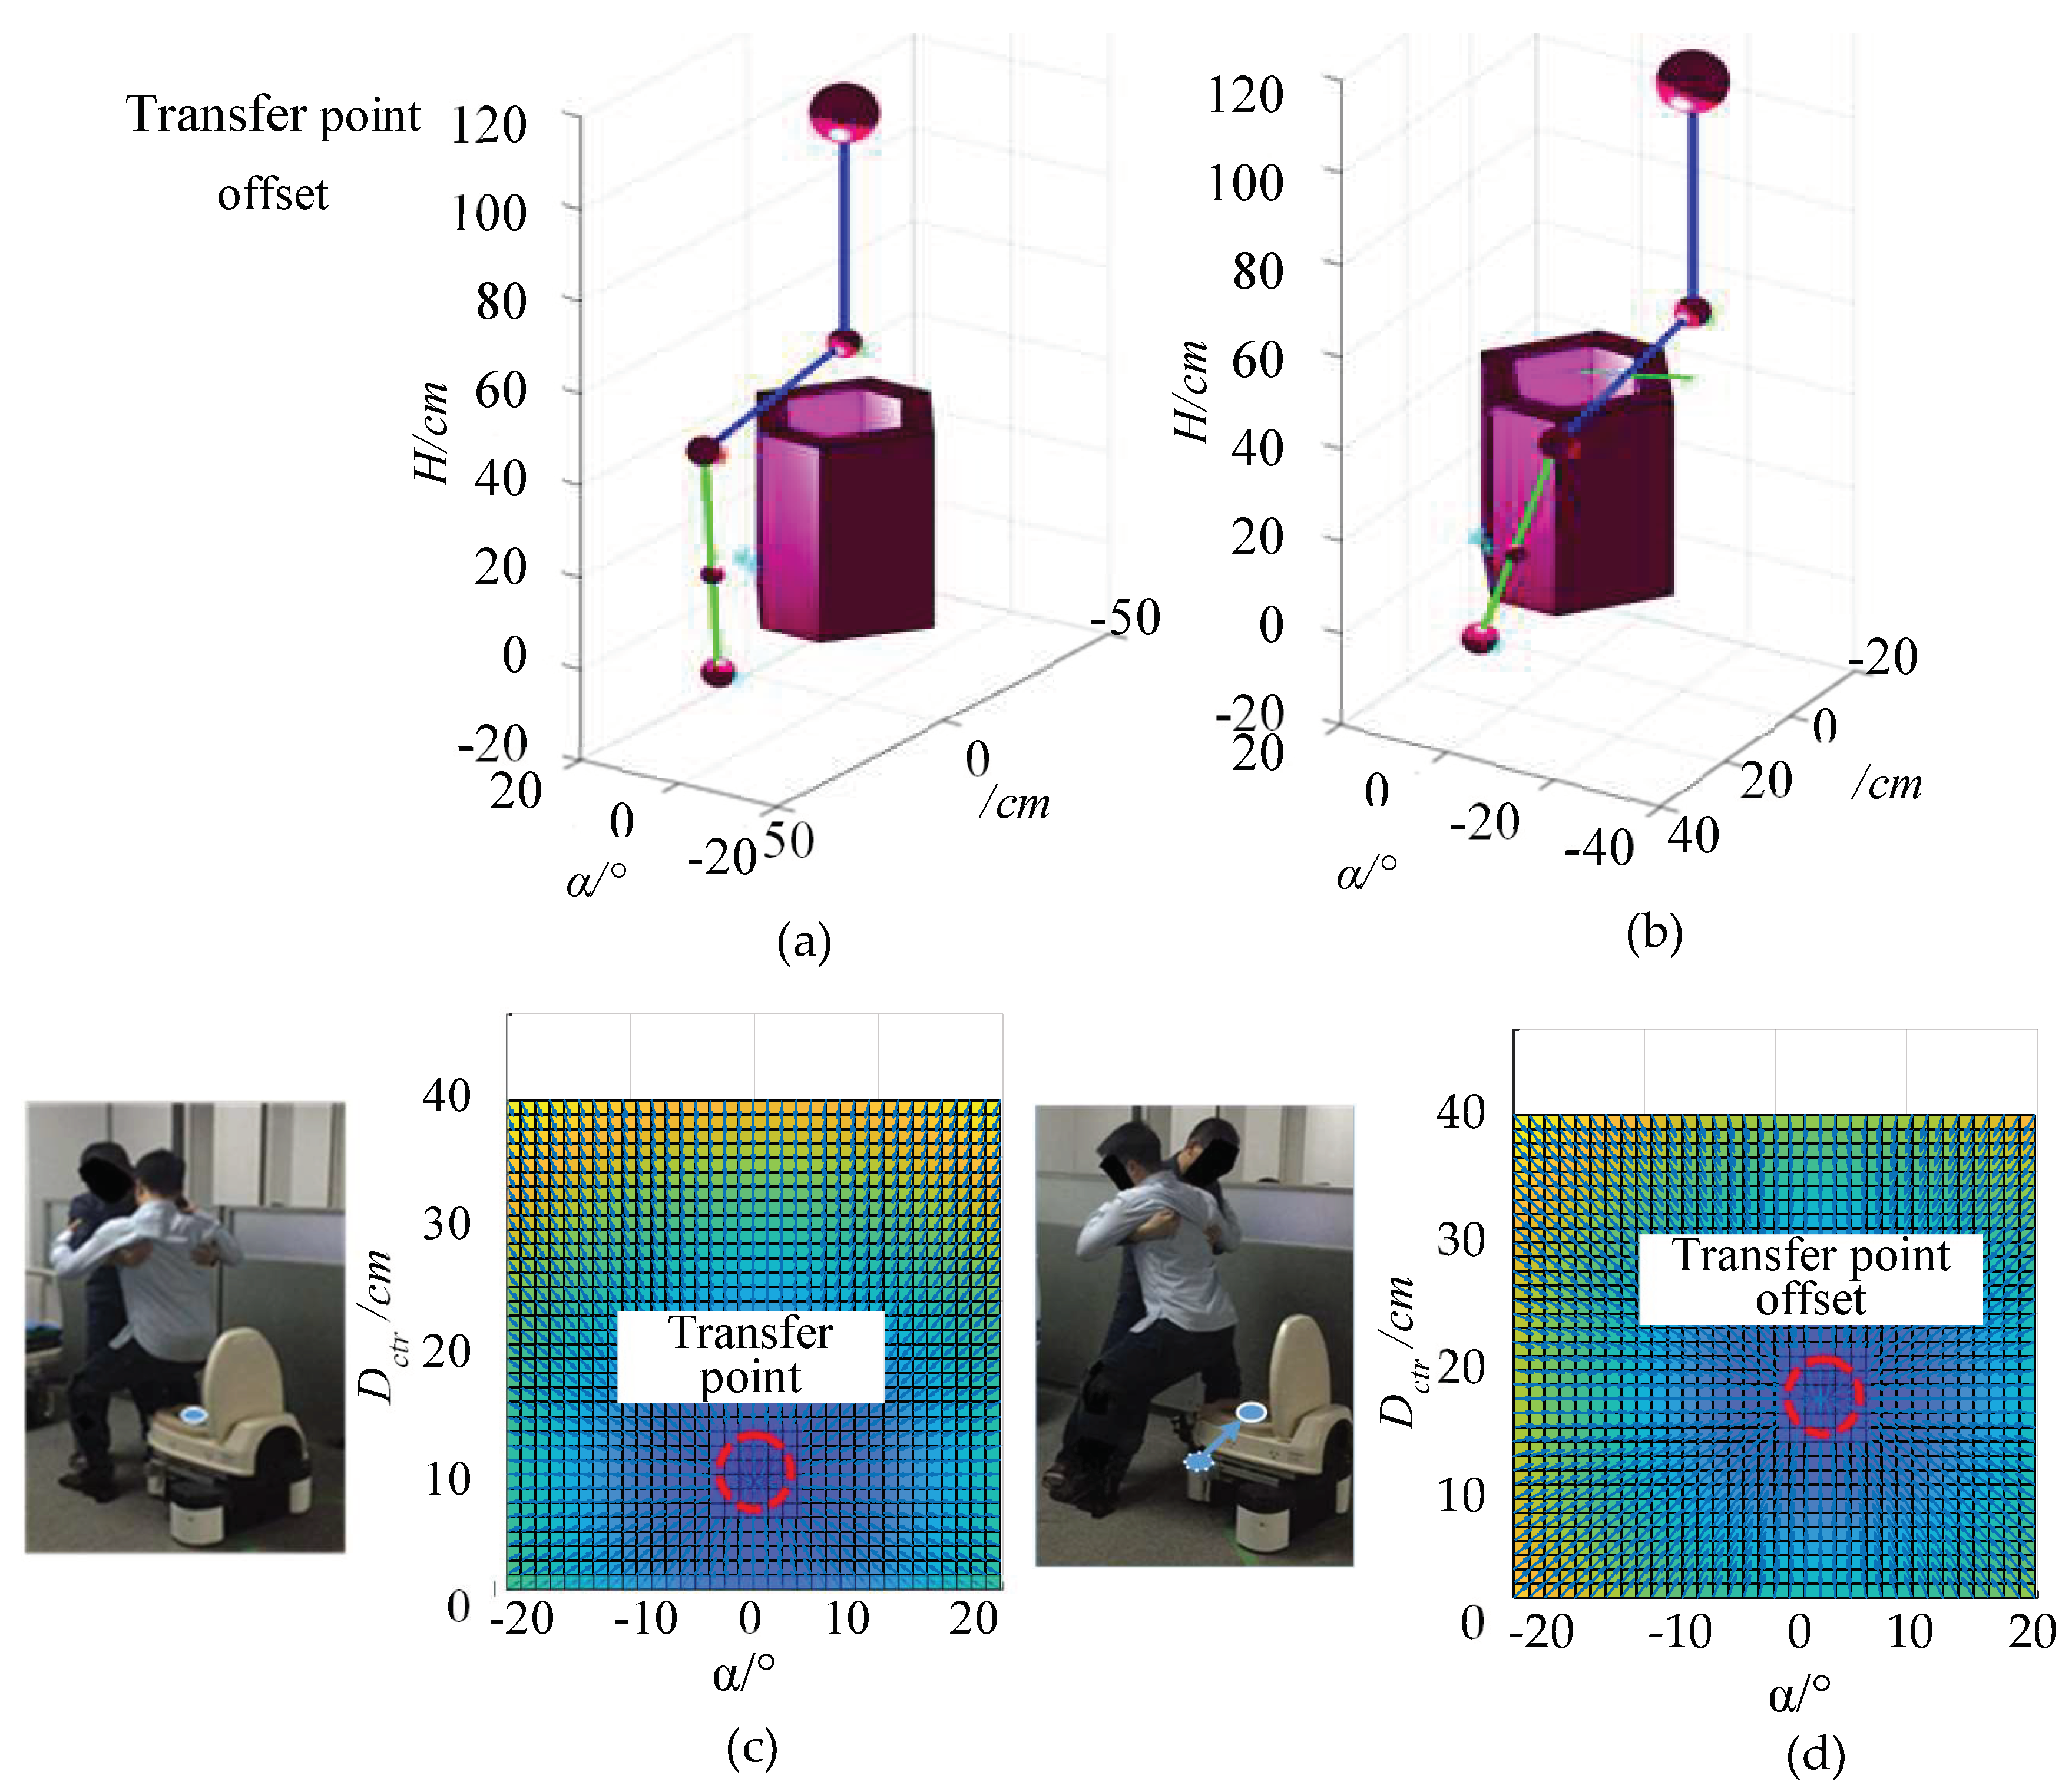
The excretion behavior in daily life for the elderly and the disabled is a high frequency, high physical load, and risky behavior. Therefore, we proposed an auxiliary lavatory robot (ALR) with autonomous movement and self-cleaning capability. When the nursing staff assists a user in transferring from a standing or lying state to sitting on the ALR, the ALR can follow the user according to their position and posture. Over the whole transfer process, the ALR always provides the user with the best transfer position and posture, which is an effective approach to reduce workload and physical load. However, confusion and occlusion of the lower limbs between the nursing staff and the user would affect the user’s posture recognition. First, in this paper, a method combined with object segmentation and shape constraint was proposed to extract the contour of the lower limbs of the user and the nursing staff. Then, depending on the position constraint and dynamic characteristics of the legs contour and back contour of the user, a dynamic posture recognition approach based on a two-level joint probabilistic data association algorithm (JPDA) was proposed. Finally, the leg target recognition experiment, path-tracking experiment, and auxiliary excretion transfer experiment were implemented to verify the effectiveness and robustness of our proposed algorithm. The experimental results showed that our proposed method improved the safety and convenience of the user, and it also reduced the workload and physical load of the nursing staff. The ALR, integrated with the proposed method, has a good universal property for the elderly and disabled with weak motion capability in hospitals, pension centers, and families.
Keywords: auxiliary lavatory robot (ALR); transfer; safety; robustness auxiliary lavatory robot (ALR); transfer; safety; robustness