Article

Pole-Like Objects Segmentation and Multiscale Classification-Based Fusion from Mobile Point Clouds in Road Scenes
1
Key Lab. of Virtual Geographical Environment, Ministry of Education, Nanjing Normal University, Nanjing 210023, China
2
Jiangsu Center for Collaborative Innovation in Geographical Information Resource Development and Application, Nanjing 210023, China
*
Author to whom correspondence should be addressed.
Remote Sens. 2021, 13(21), 4382; https://doi.org/10.3390/rs13214382
Submission received: 7 September 2021 / Revised: 14 October 2021 / Accepted: 28 October 2021 / Published: 30 October 2021
(This article belongs to the Special Issue Laser Scanning and Point Cloud Processing in Urban Environments)

Abstract

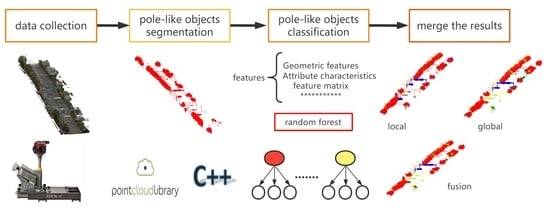
Real-time acquisition and intelligent classification of pole-like street-object point clouds are of great significance in the construction of smart cities. Efficient point cloud processing technology in road scenes can accelerate the development of intelligent transportation and promote the development of high-precision maps. However, available algorithms have the problems of incomplete extraction and the low recognition accuracy of pole-like objects. In this paper, we propose a segmentation method of pole-like objects under geometric structural constraints. As for classification, we fused the classification results at different scales with each other. First, the point cloud data excluding ground point clouds were divided into voxels, and the rod-shaped parts of the pole-like objects were extracted according to the vertical continuity. Second, the regional growth based on the voxel was carried out based on the rod part to retain the non-rod part of the pole-like objects. A one-way double coding strategy was adopted to preserve the details. For spatial overlapping entities, we used multi-rule supervoxels to divide them. Finally, the random forest model was used to classify the pole-like objects based on local- and global-scale features and to fuse the double classification results under the different scales in order to obtain the final result. Experiments showed that the proposed method can effectively extract the pole-like objects of the point clouds in the road scenes, indicating that the method can achieve high-precision classification and identification in the lightweight data. Our method can also bring processing inspiration for large data.
Keywords: road scene point clouds; pole-like objects; point cloud classification; random forest model; multiscale fusion road scene point clouds; pole-like objects; point cloud classification; random forest model; multiscale fusion
Graphical Abstract