Proceeding Paper

Error Correction Using Bayesian GRU Network in Hybrid Visual Inertial Navigation System †
1
Centre for Space Systems, Cranfield University, Bedford MK43 0AL, UK
2
Department of Mechanical Engineering, Prince Mohammad Bin Fahd University, Al Khobar 31952, Saudi Arabia
*
Author to whom correspondence should be addressed.
Presented at the European Navigation Conference 2025 (ENC 2025), Wrocław, Poland, 21–23 May 2025.
Eng. Proc. 2026, 126(1), 52; https://doi.org/10.3390/engproc2026126052

Published: 28 April 2026
(This article belongs to the Proceedings of European Navigation Conference 2025)

Abstract

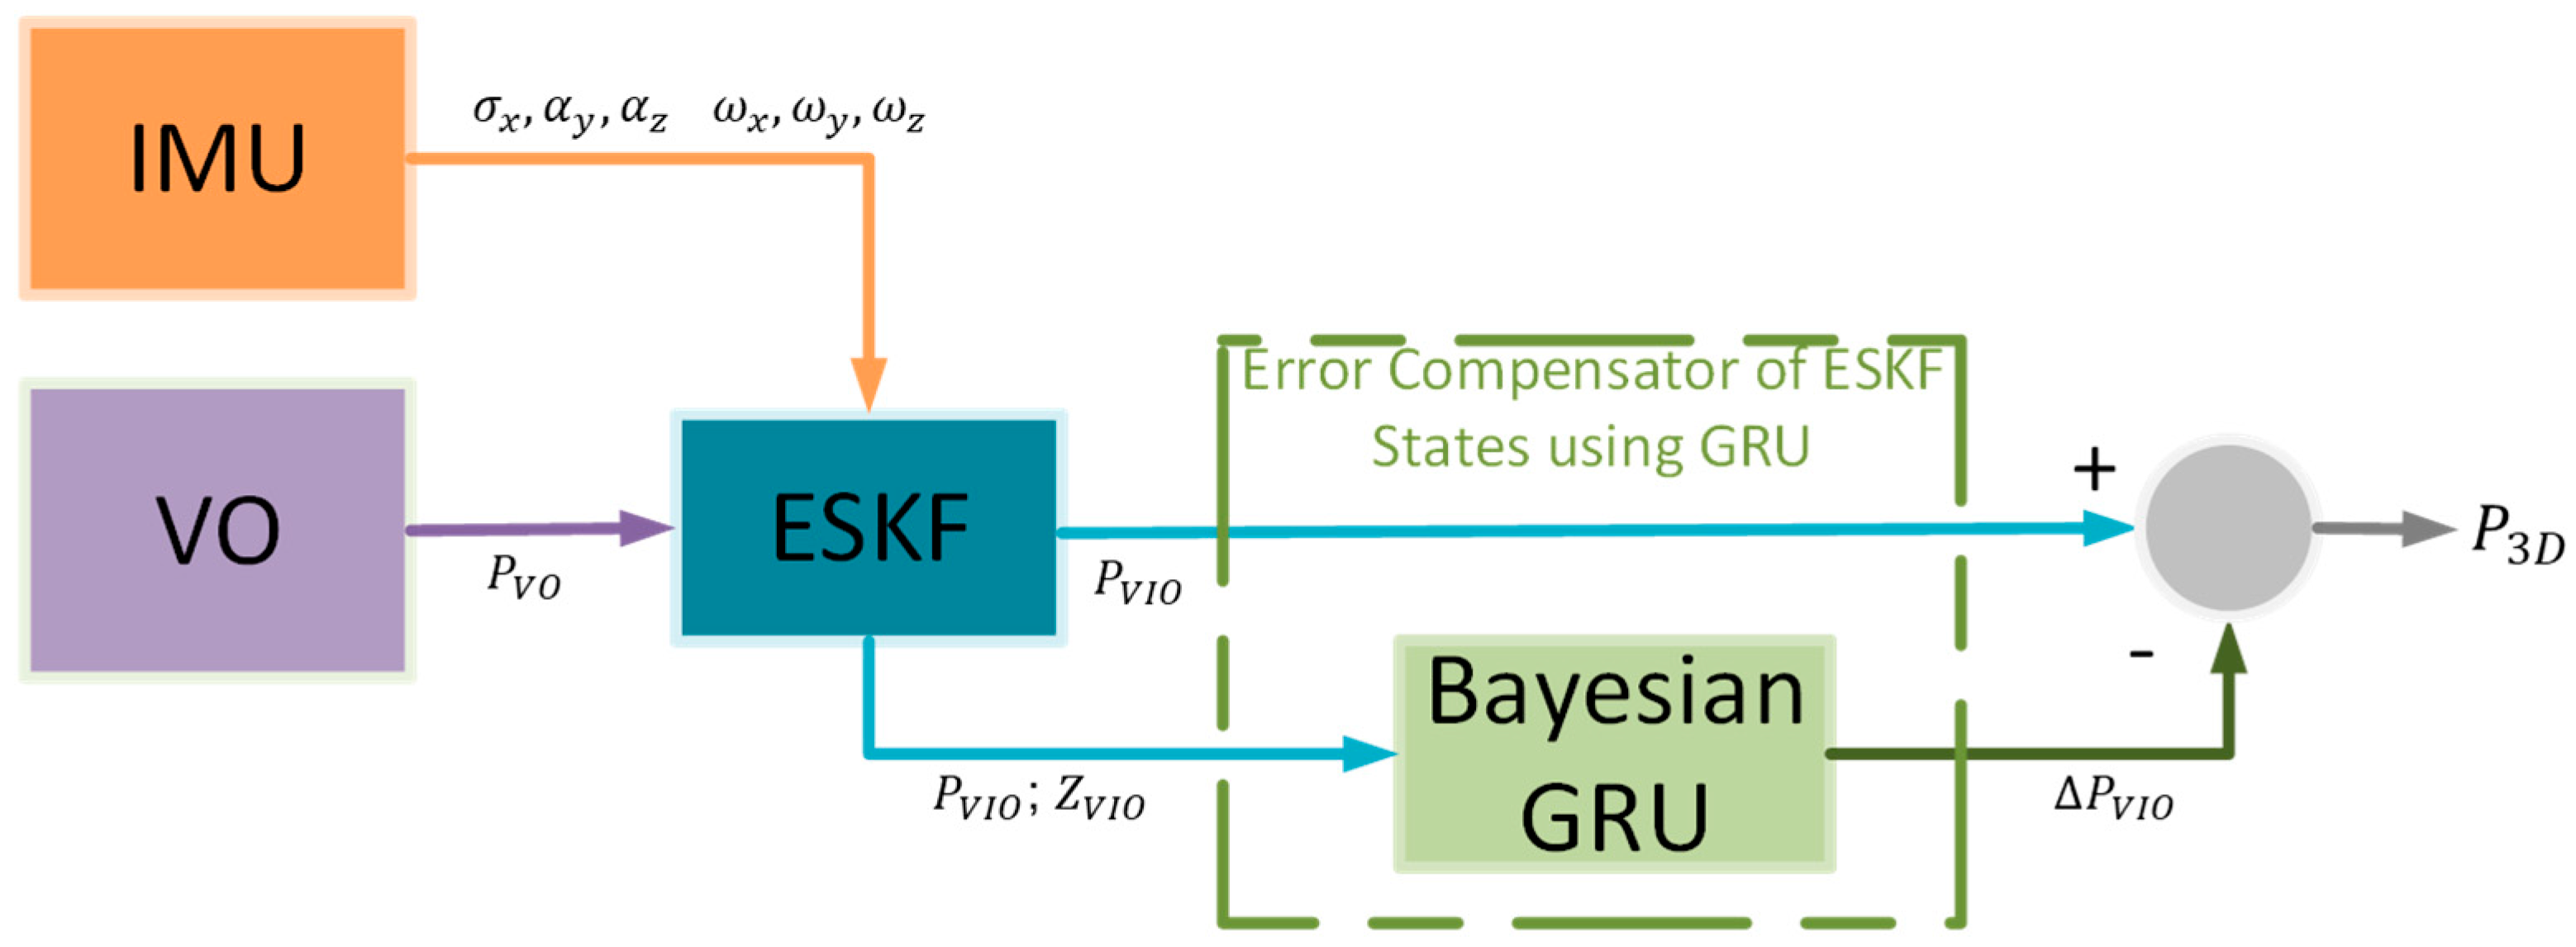
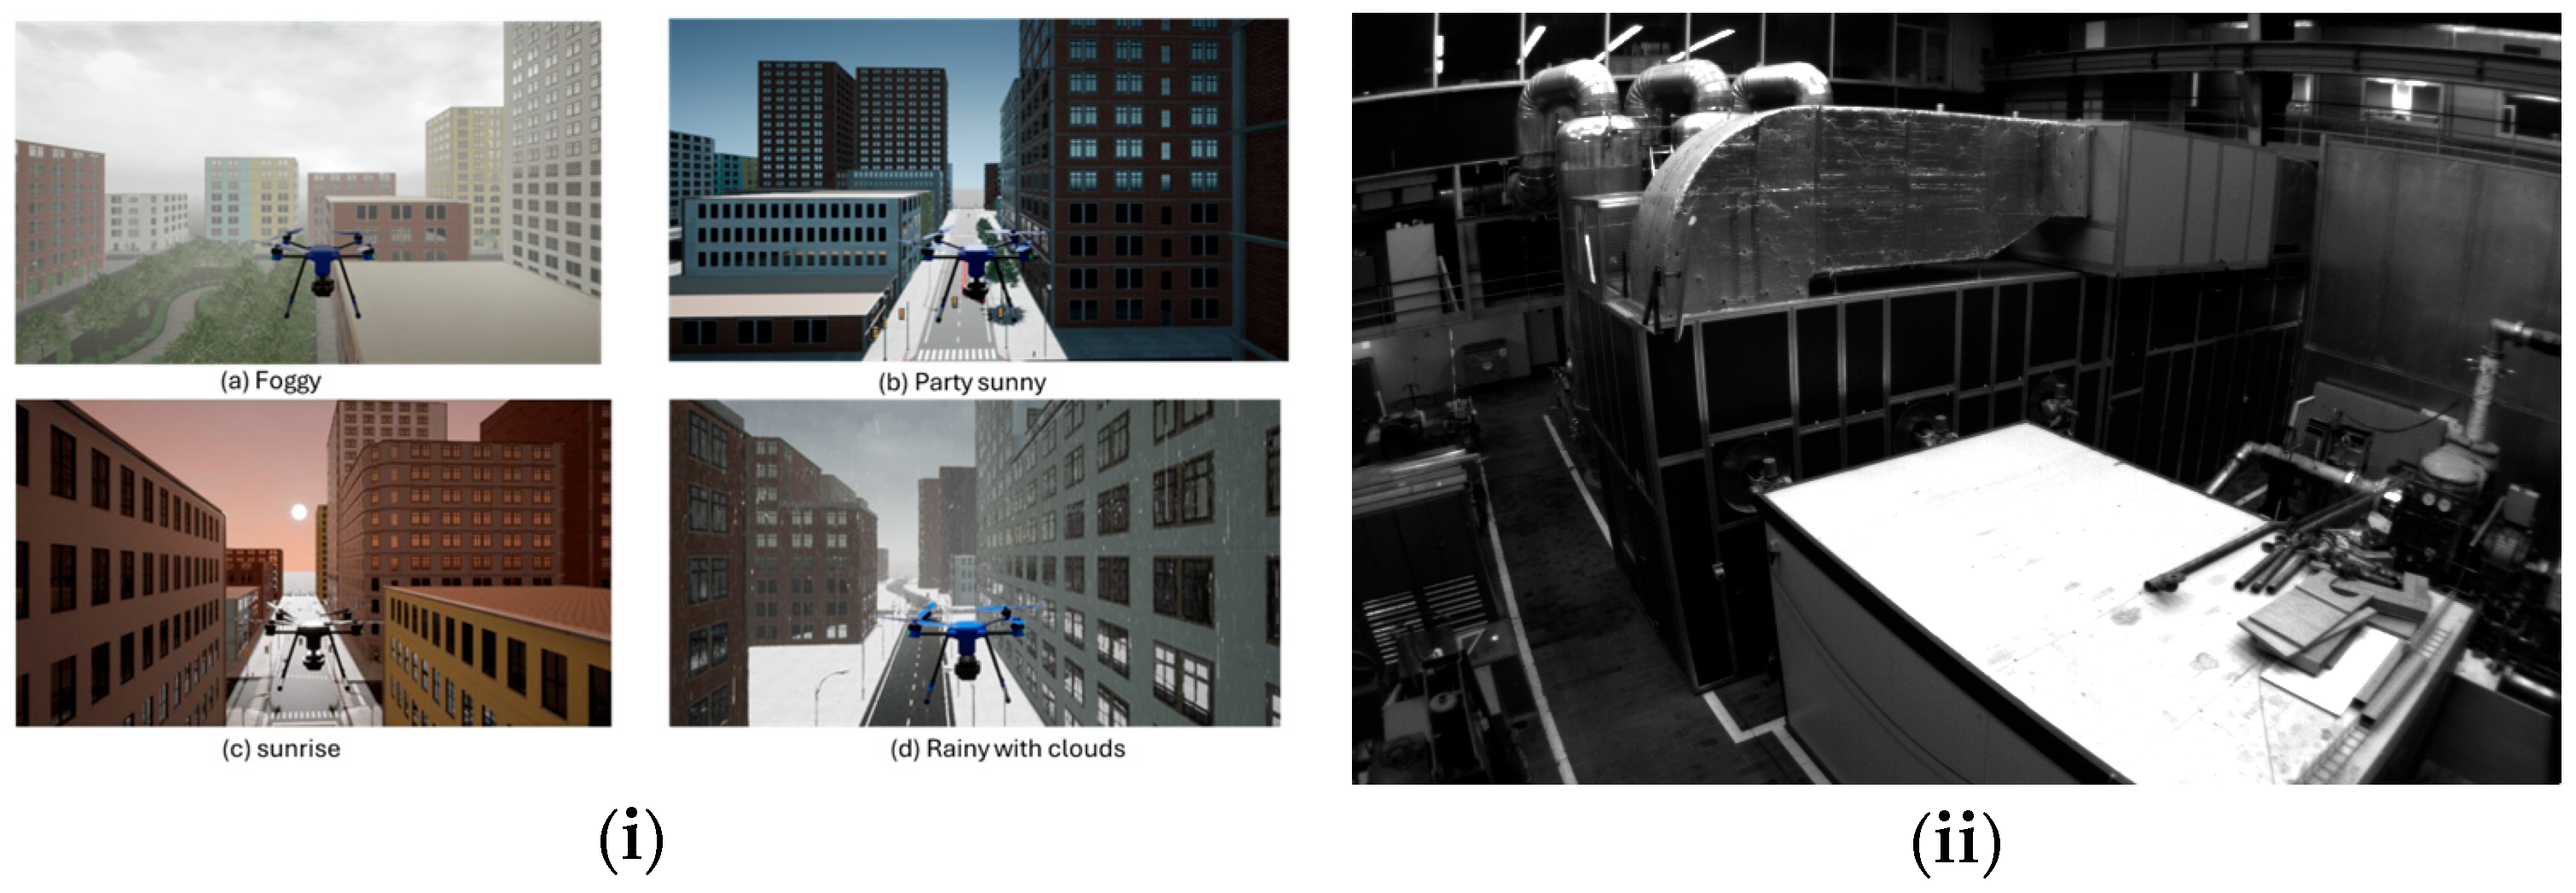
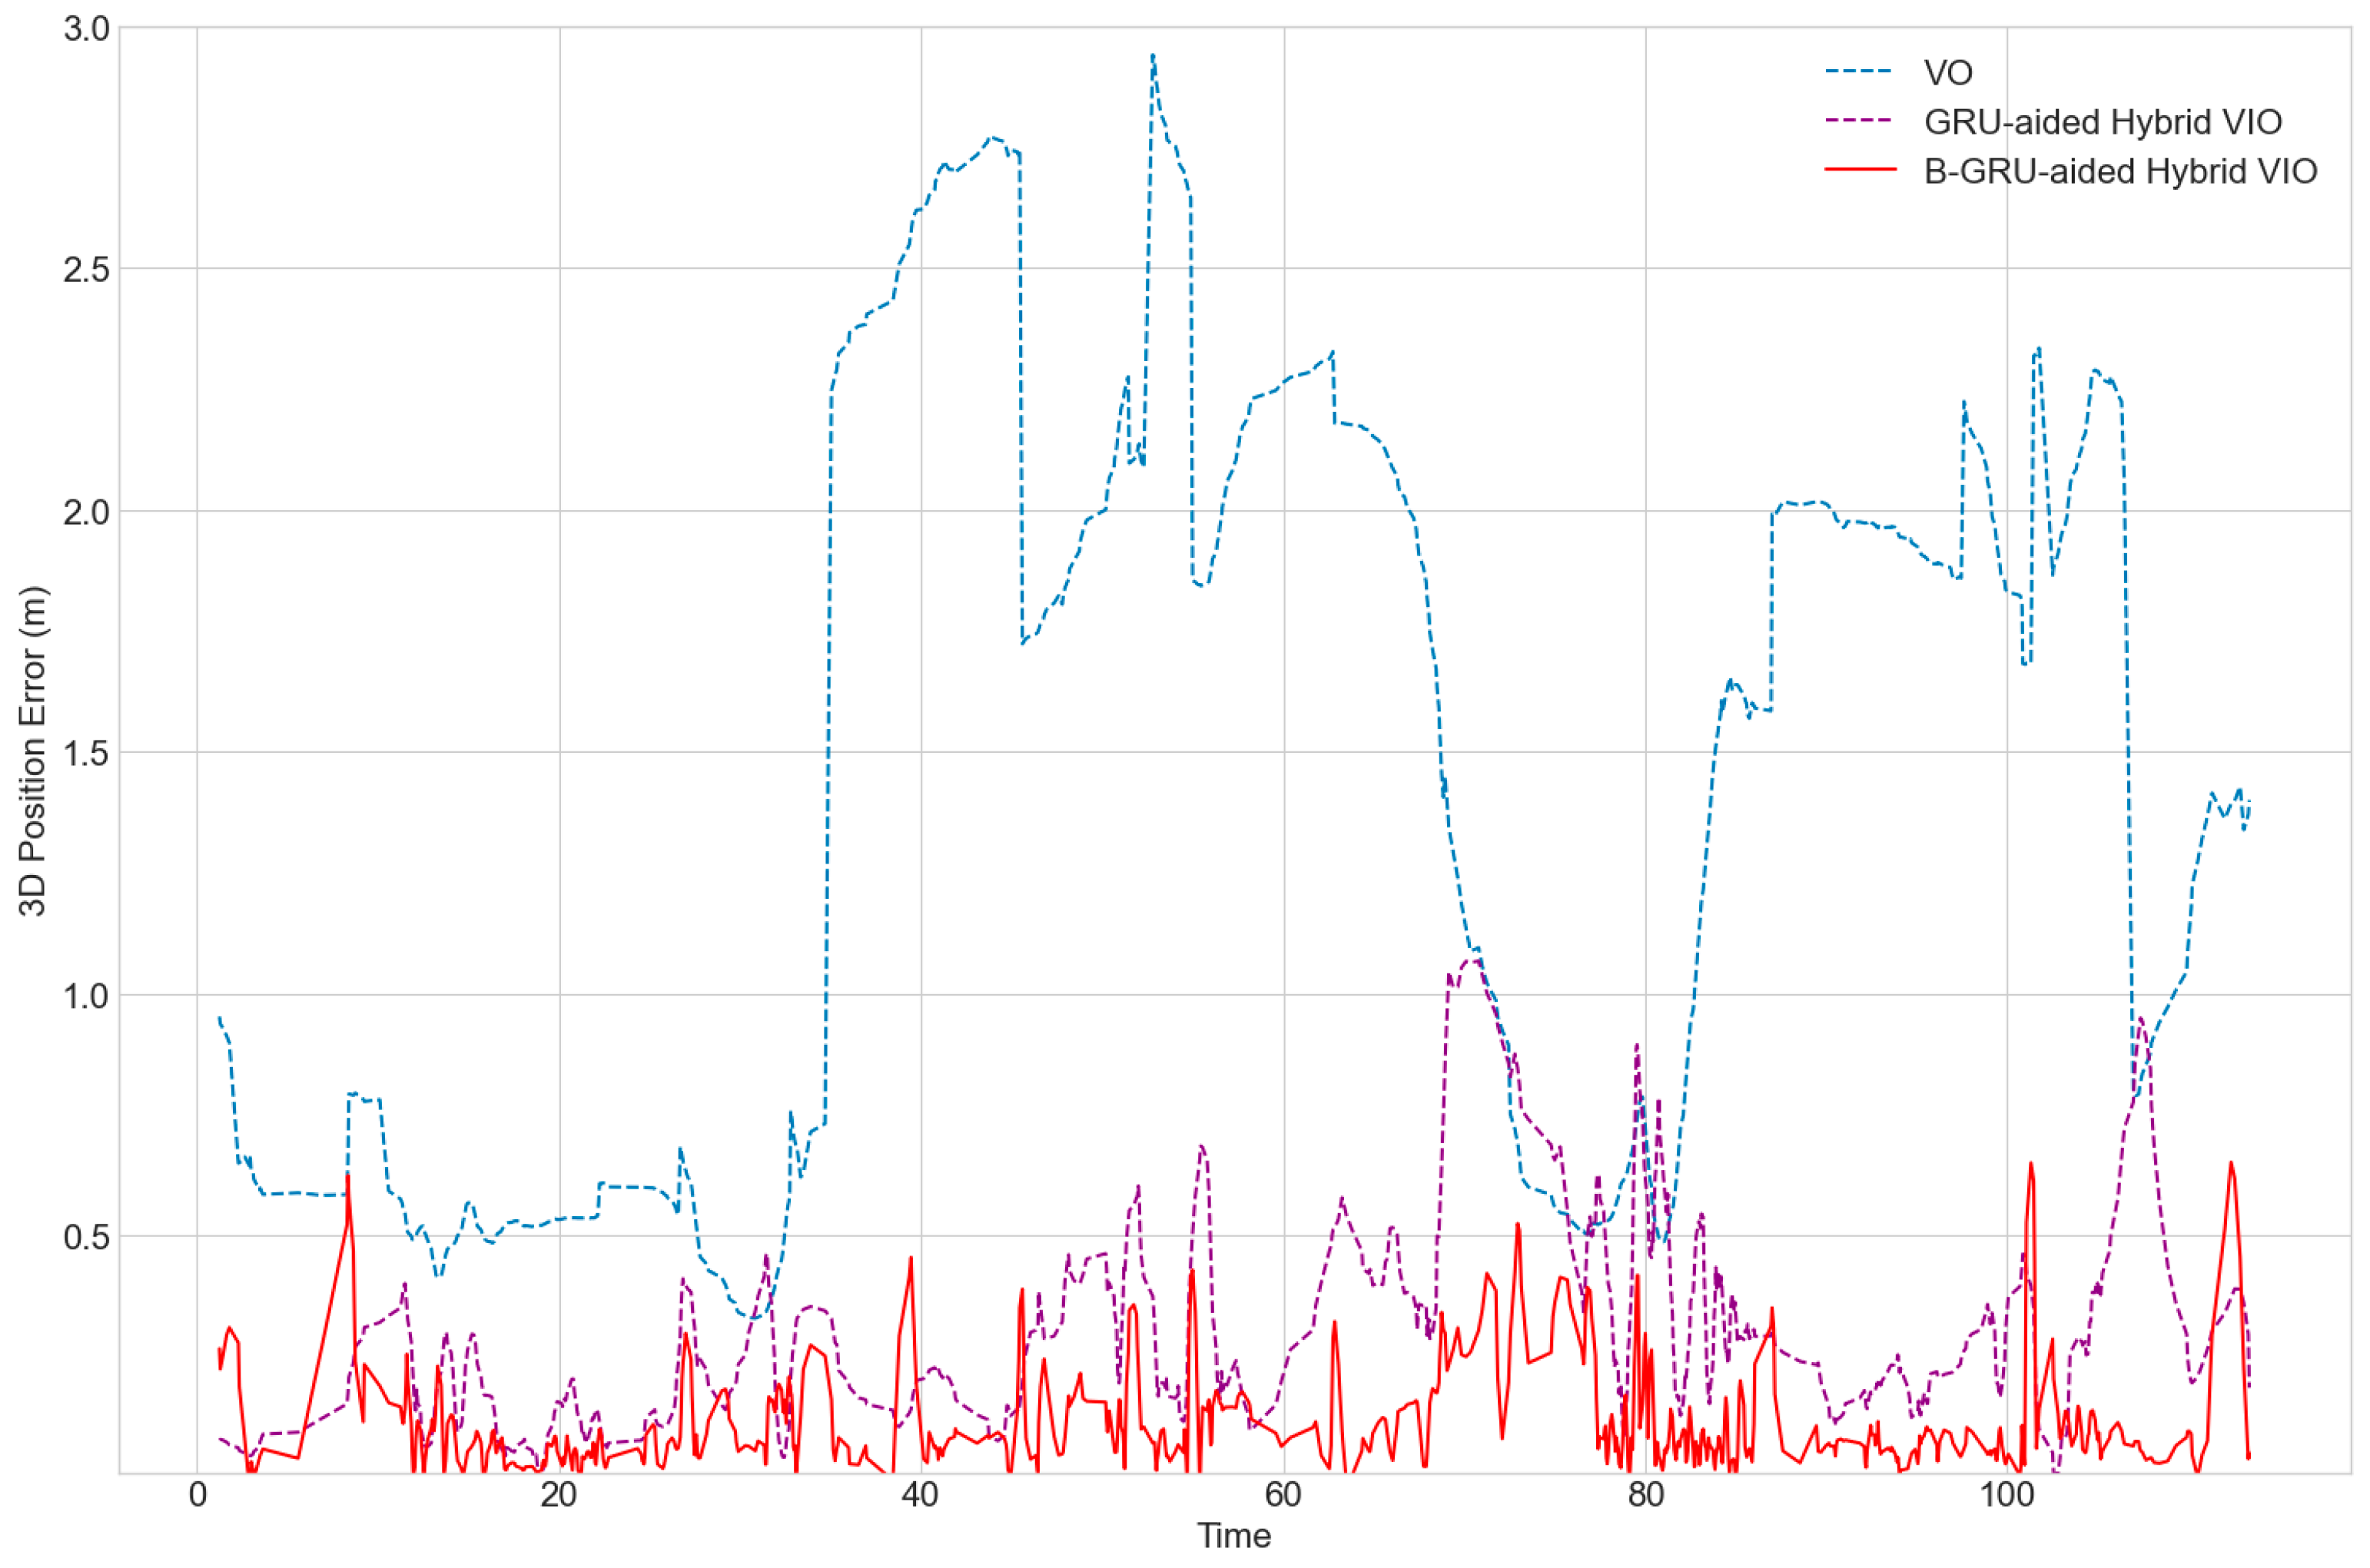
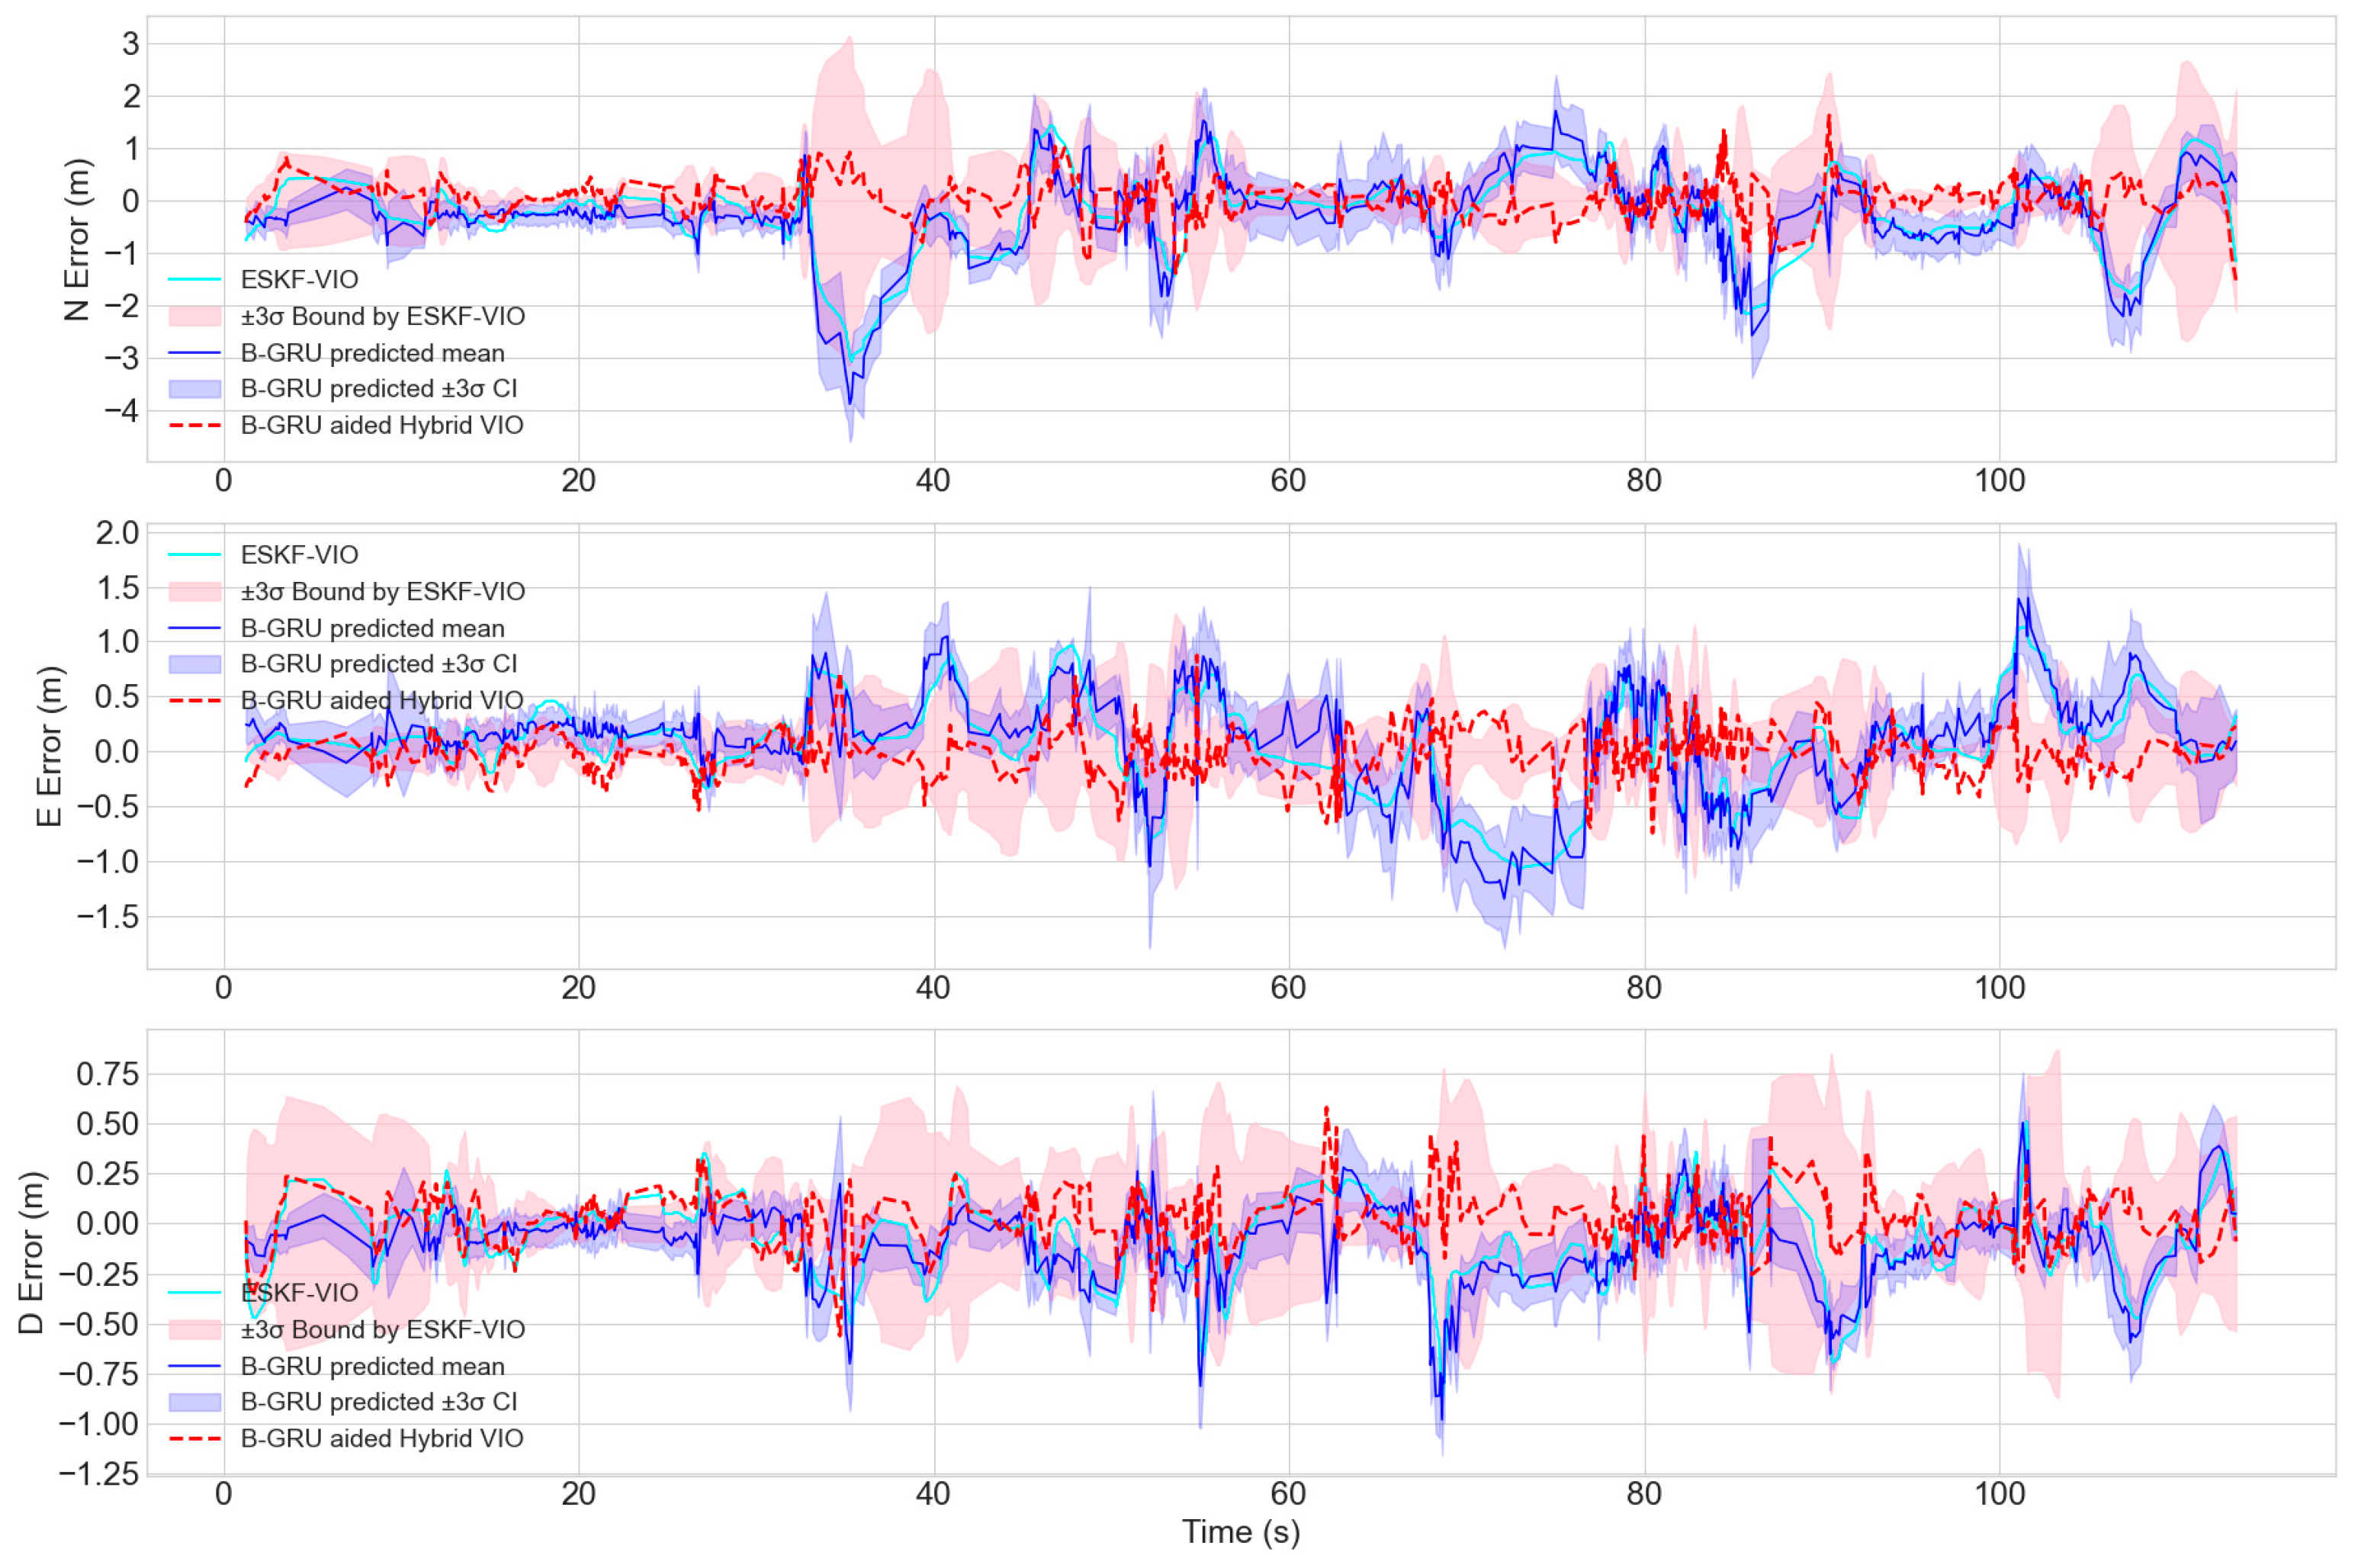
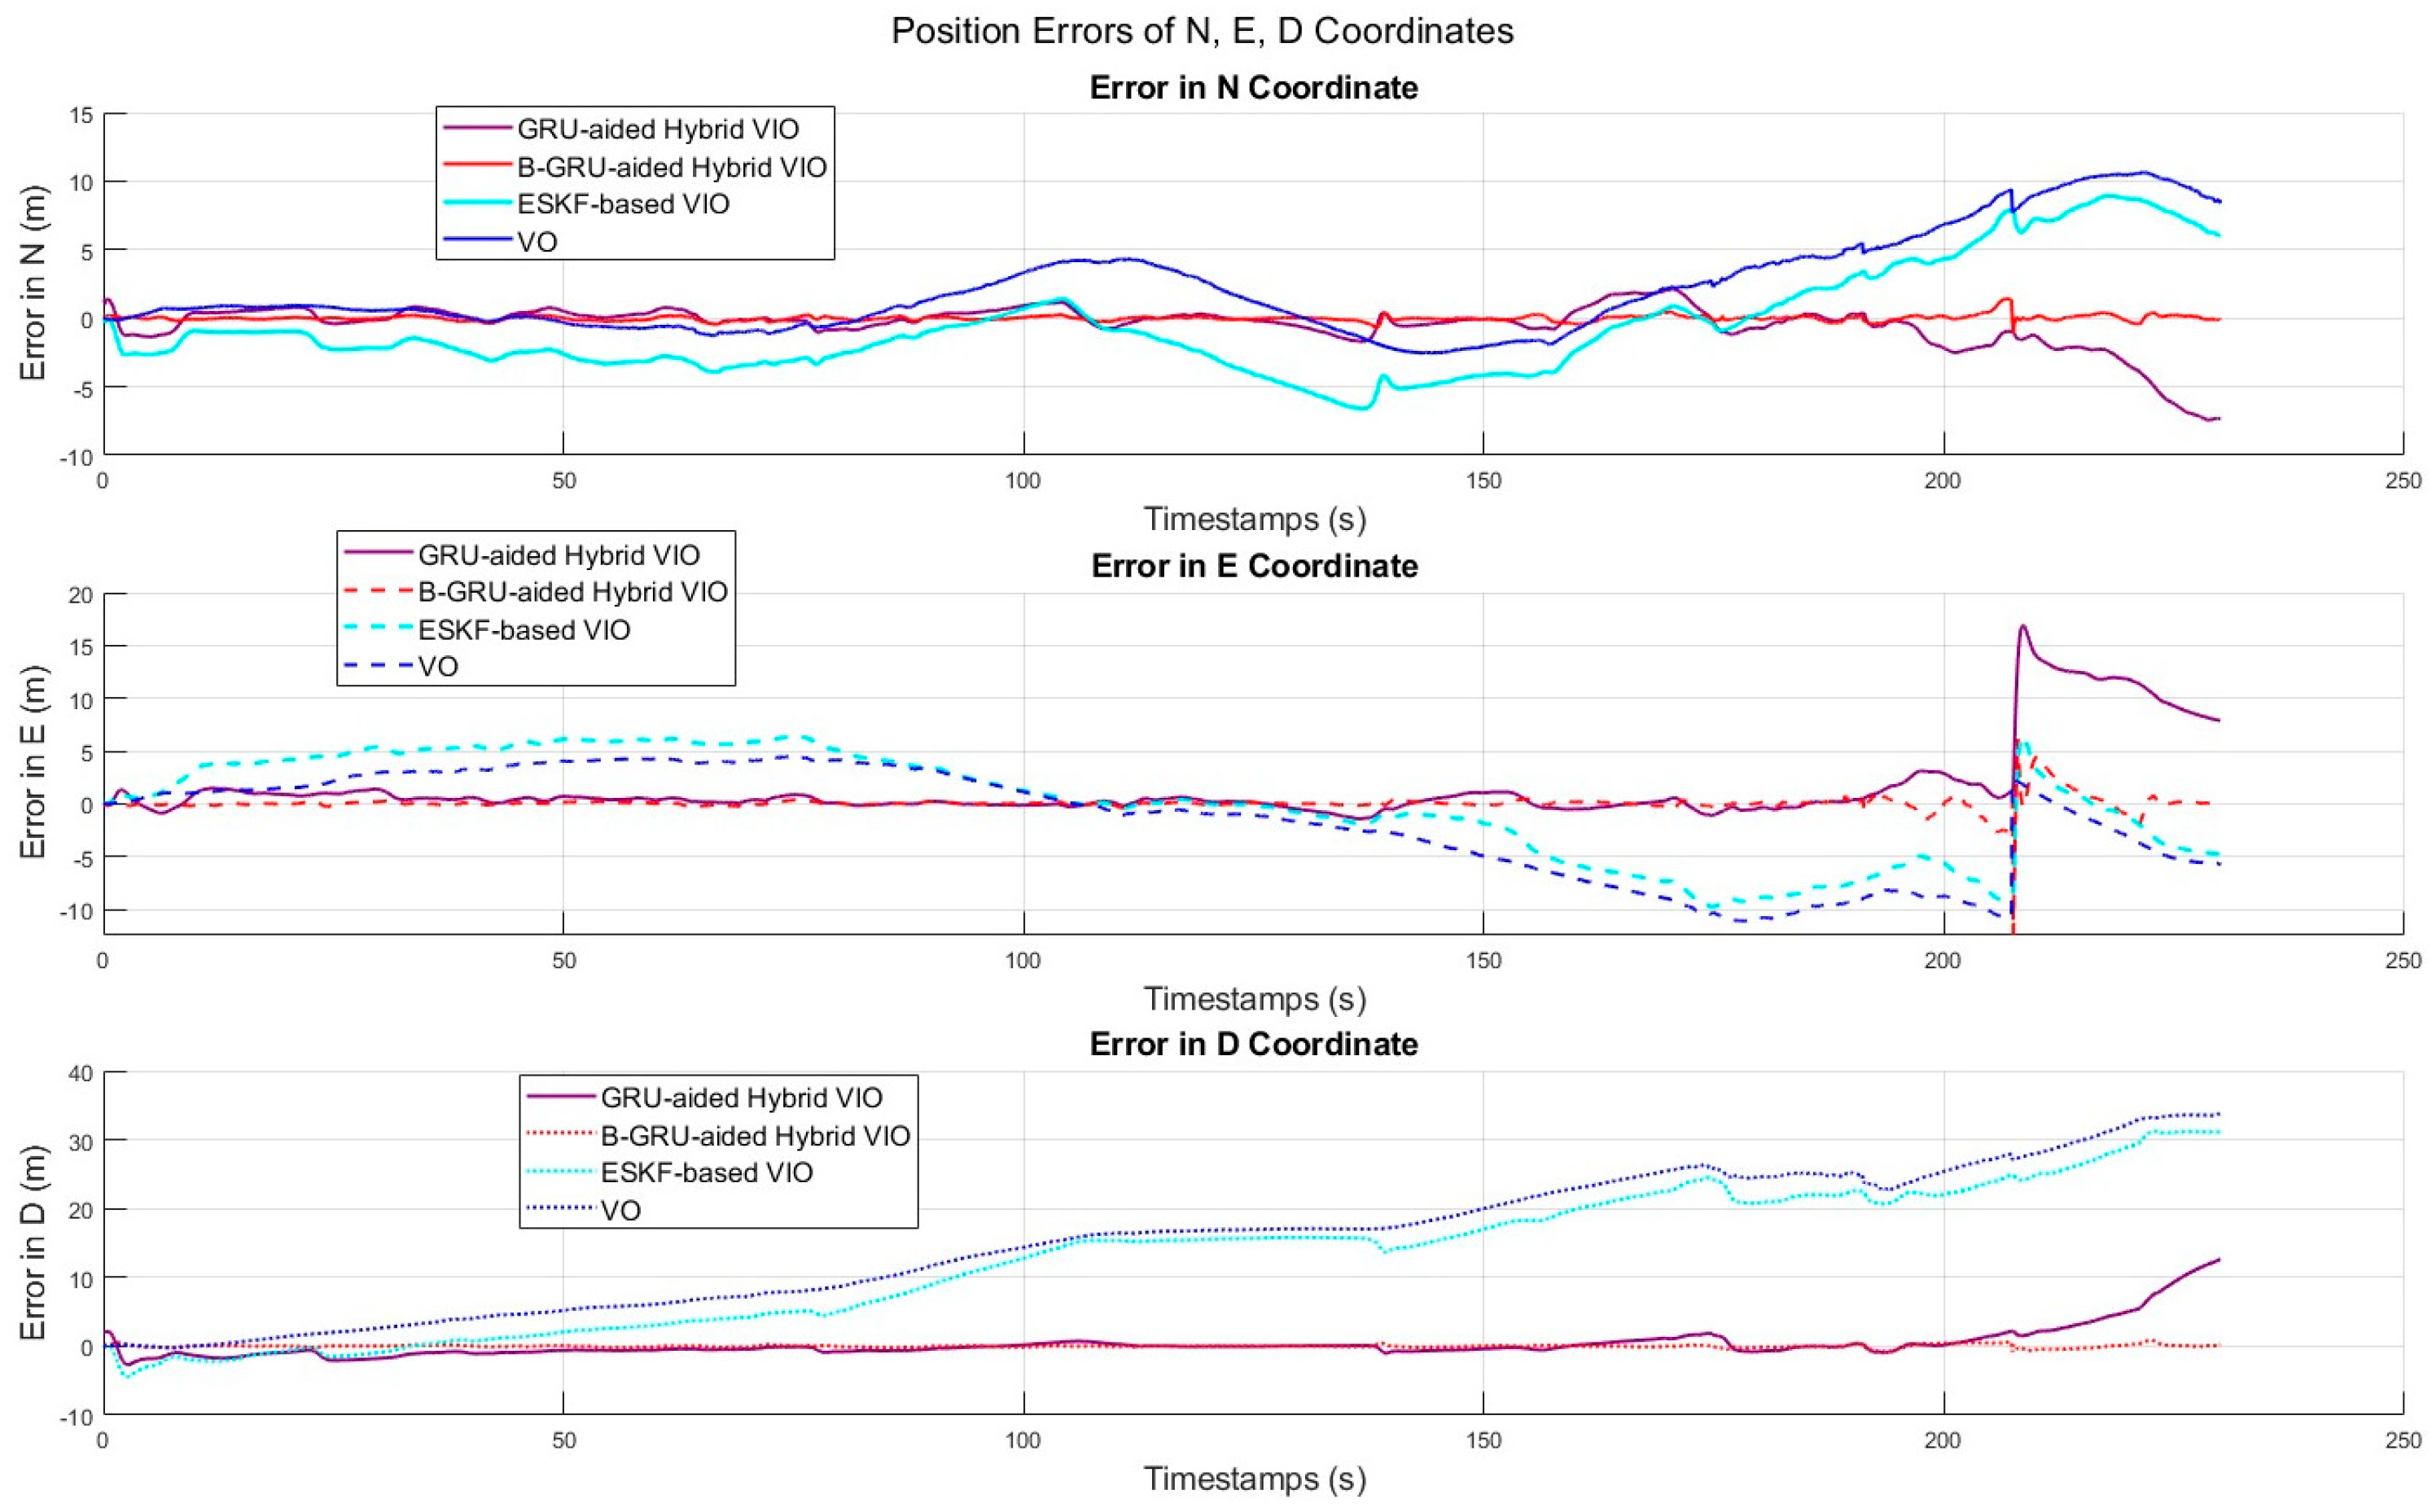
Vision-based navigation systems (VINS) are increasingly utilised as an alternative to GNSS for UAVs operating in urban environments, but they suffer from performance degradation under visual fault conditions like illumination variation, rapid motion, texture-less environments, and weather effects. While hybrid architecture incorporating Kalman filters and machine learning (ML) improves performance, they often lack evidence of providing contingency for non-Gaussian error distributions, limiting operational safety. To address these shortcomings, an enhanced hybrid VINS architecture is proposed, featuring a Bayesian GRU-based error correction network (B-GRU) to provide a contingency while compensating model errors. To the best of the authors’ knowledge, this is the first attempt to estimate uncertainty using a B-GRU compensator while addressing data uncertainty for VINS applications. The system architecture integrates an Error-State Kalman Filter (ESKF) and the B-GRU, compensating for position errors with uncertainty prediction. The proposed approach is validated using datasets from MATLAB incorporated in an Unreal Engine simulated environment, replicating the complex fault conditions. The ML model is trained on various visual failure modes to adapt the variability in the signal patterns during flights with simulated datasets and tested across varied flight paths and lighting scenarios. The results demonstrate that the fusion strategy effectively corrects erroneous measurements arising from corrupted sensor data and imperfect models and achieves an improvement of 78.06% compared to SOTA hybrid VIO on the horizontal axis while capturing complex flight dynamics in an unseen environment. A comparative analysis demonstrates the effectiveness of B-GRU in mitigating failure modes with a predictive error boundary, achieving a 72% improvement in performance compared to the architecture that integrates GRU-based error compensation. This approach shows a step forward in enhancing positioning accuracy and contingency in challenging urban environments.
Keywords: error compensation; Visual Inertial Odometry; Bayesian GRU; failure modes; Error State Kalman Filter; uncertainty error compensation; Visual Inertial Odometry; Bayesian GRU; failure modes; Error State Kalman Filter; uncertainty