Article

Dual Observer Based Adaptive Controller for Hybrid Drones

1
Department of Electrical Engineering, Institute of Infrastructure Technology Research and Management (IITRAM), Ahmedabad 380026, India
2
Department of Cybernetics and Biomedical Engineering, Faculty of Electrical Engineering and Computer Science, VSB-Technical University of Ostrava, 17. Listopadu 2172/15, 708 00 Ostrava-Poruba, Czech Republic
*
Author to whom correspondence should be addressed.
Drones 2023, 7(1), 48; https://doi.org/10.3390/drones7010048
Submission received: 23 November 2022 / Revised: 1 January 2023 / Accepted: 4 January 2023 / Published: 11 January 2023

Abstract

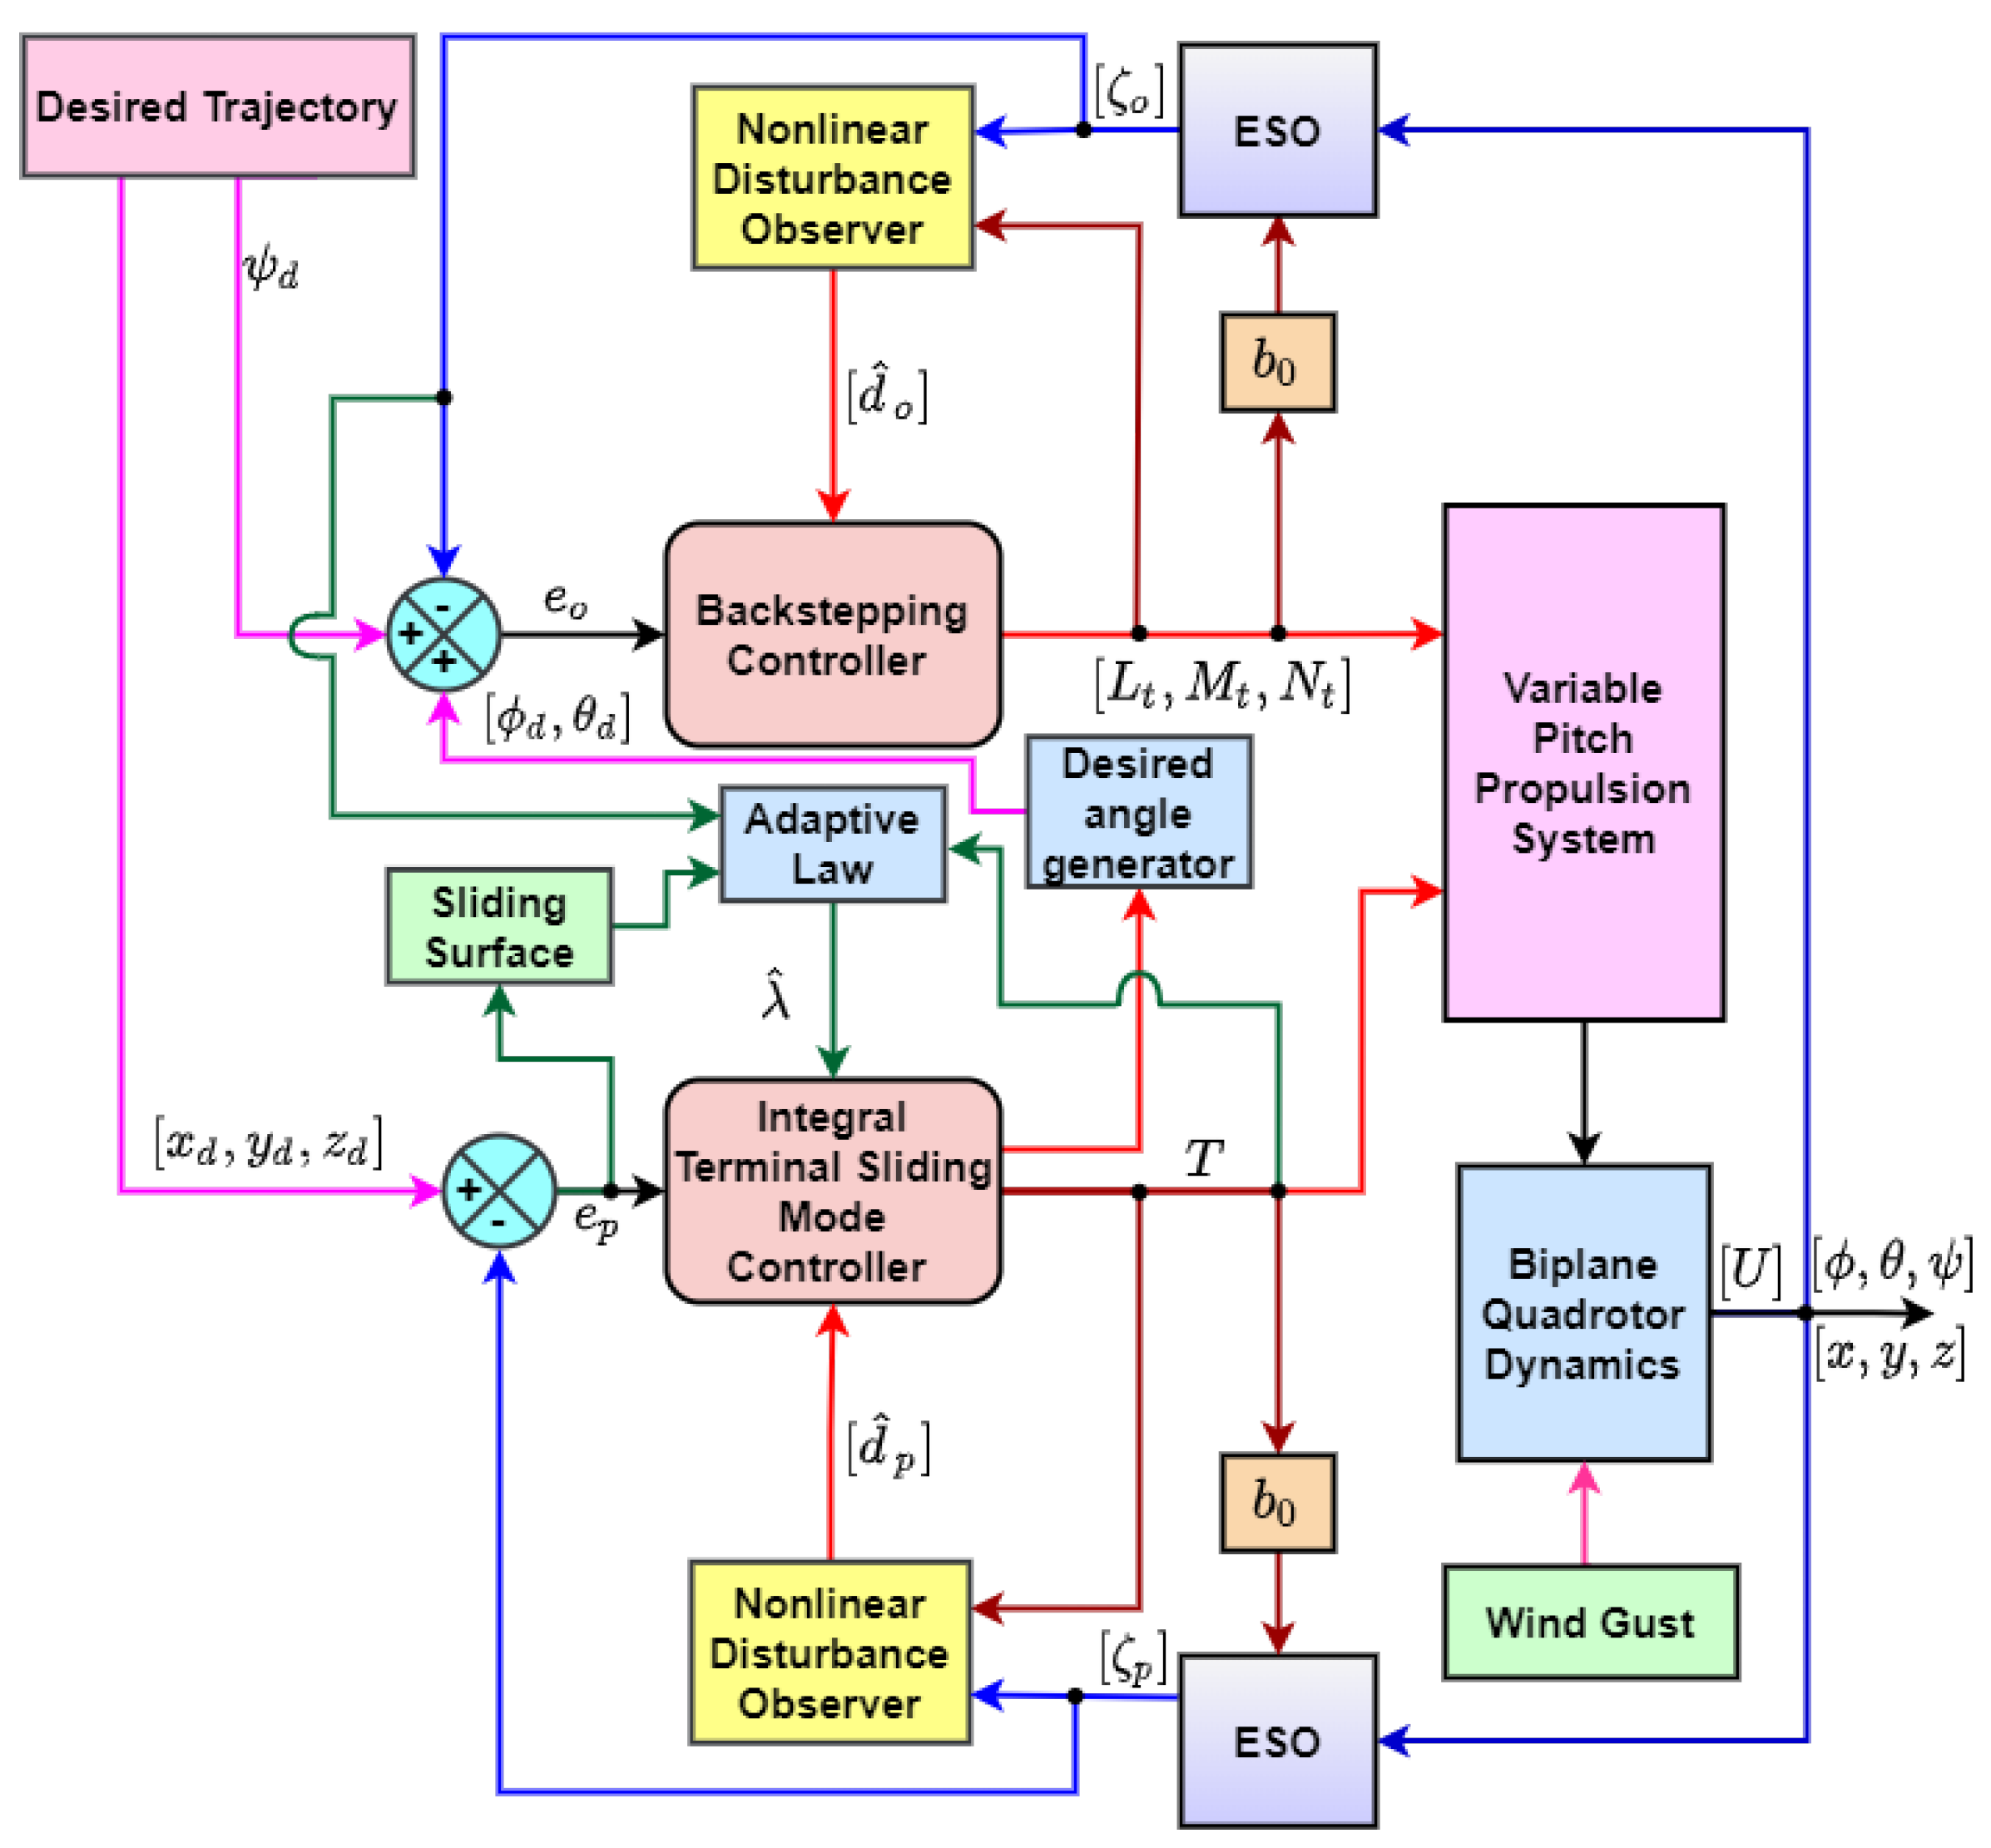
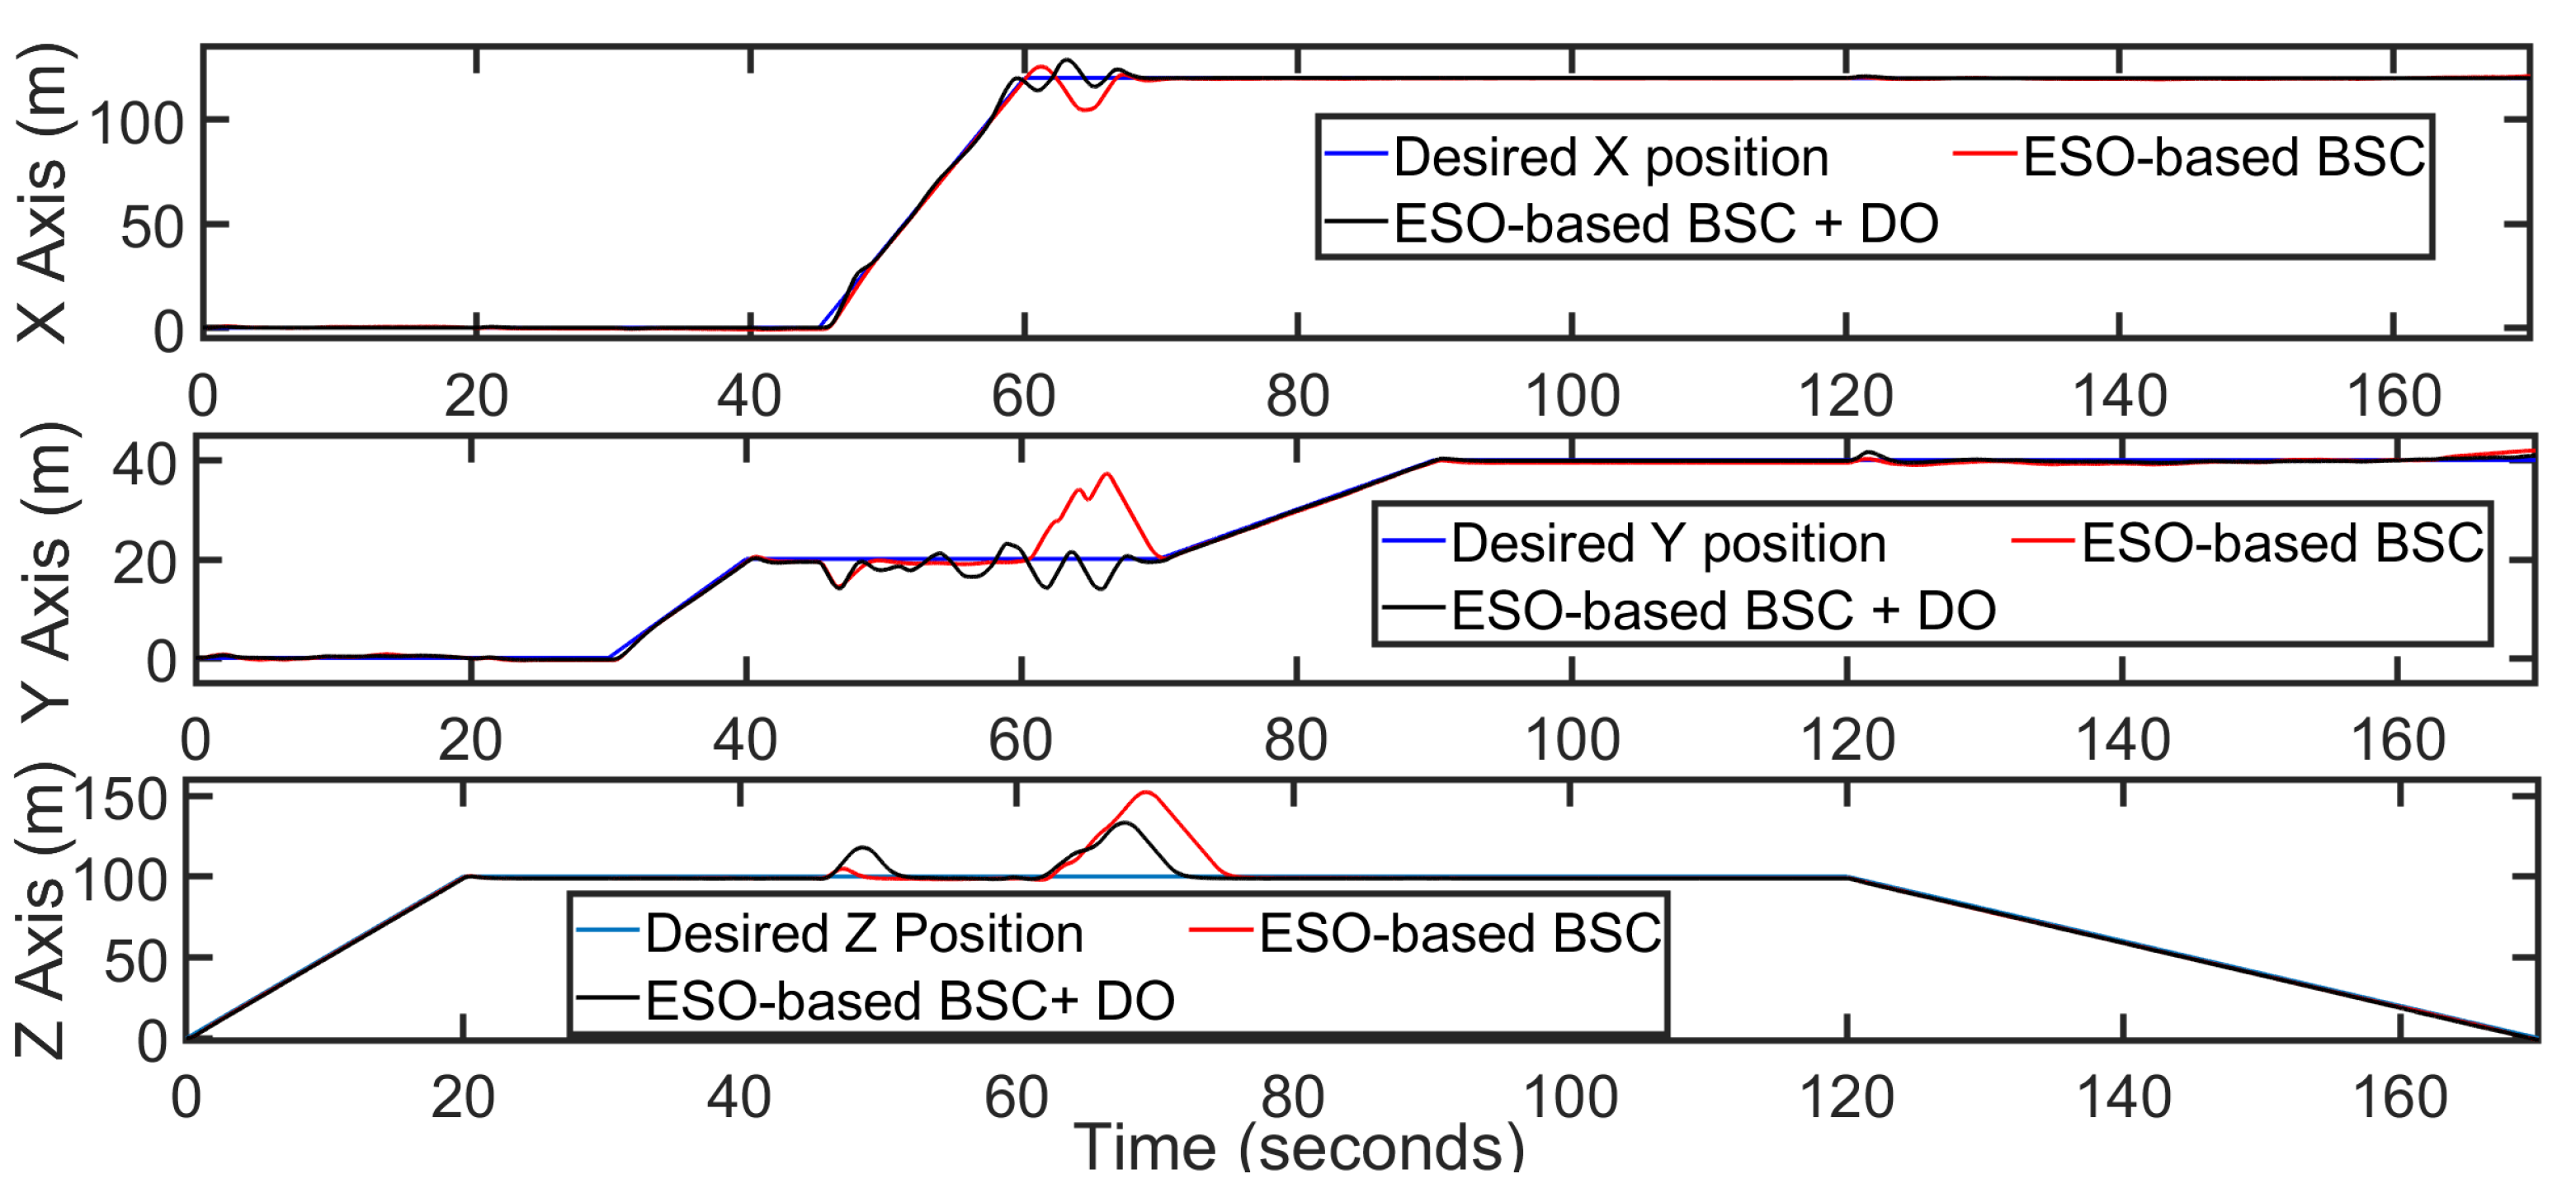
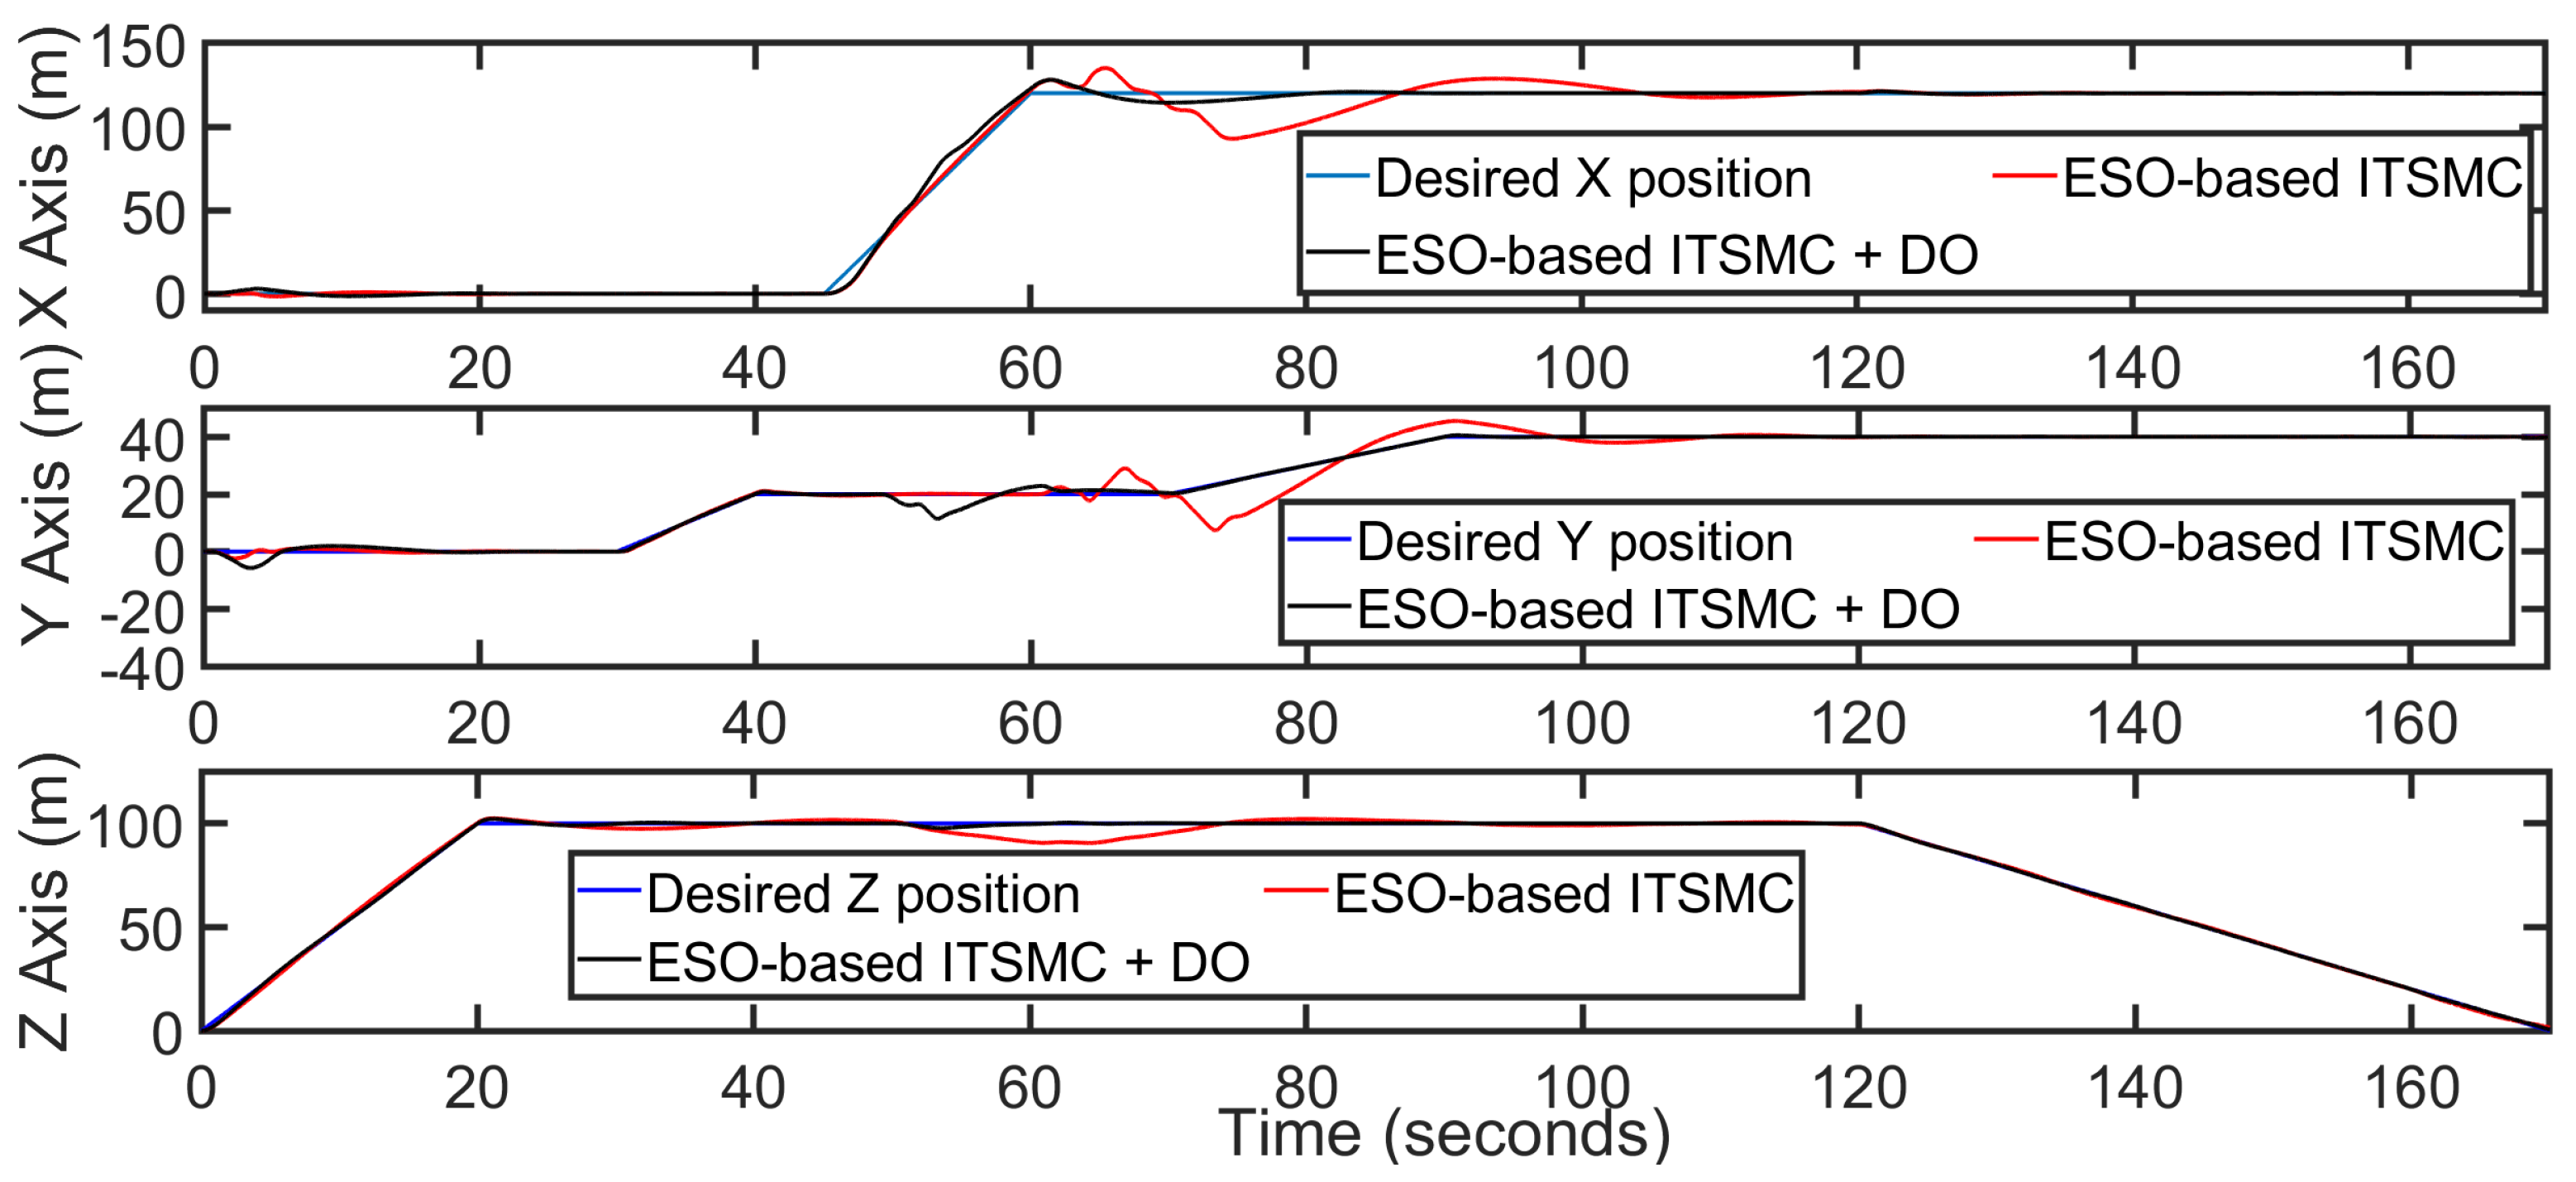
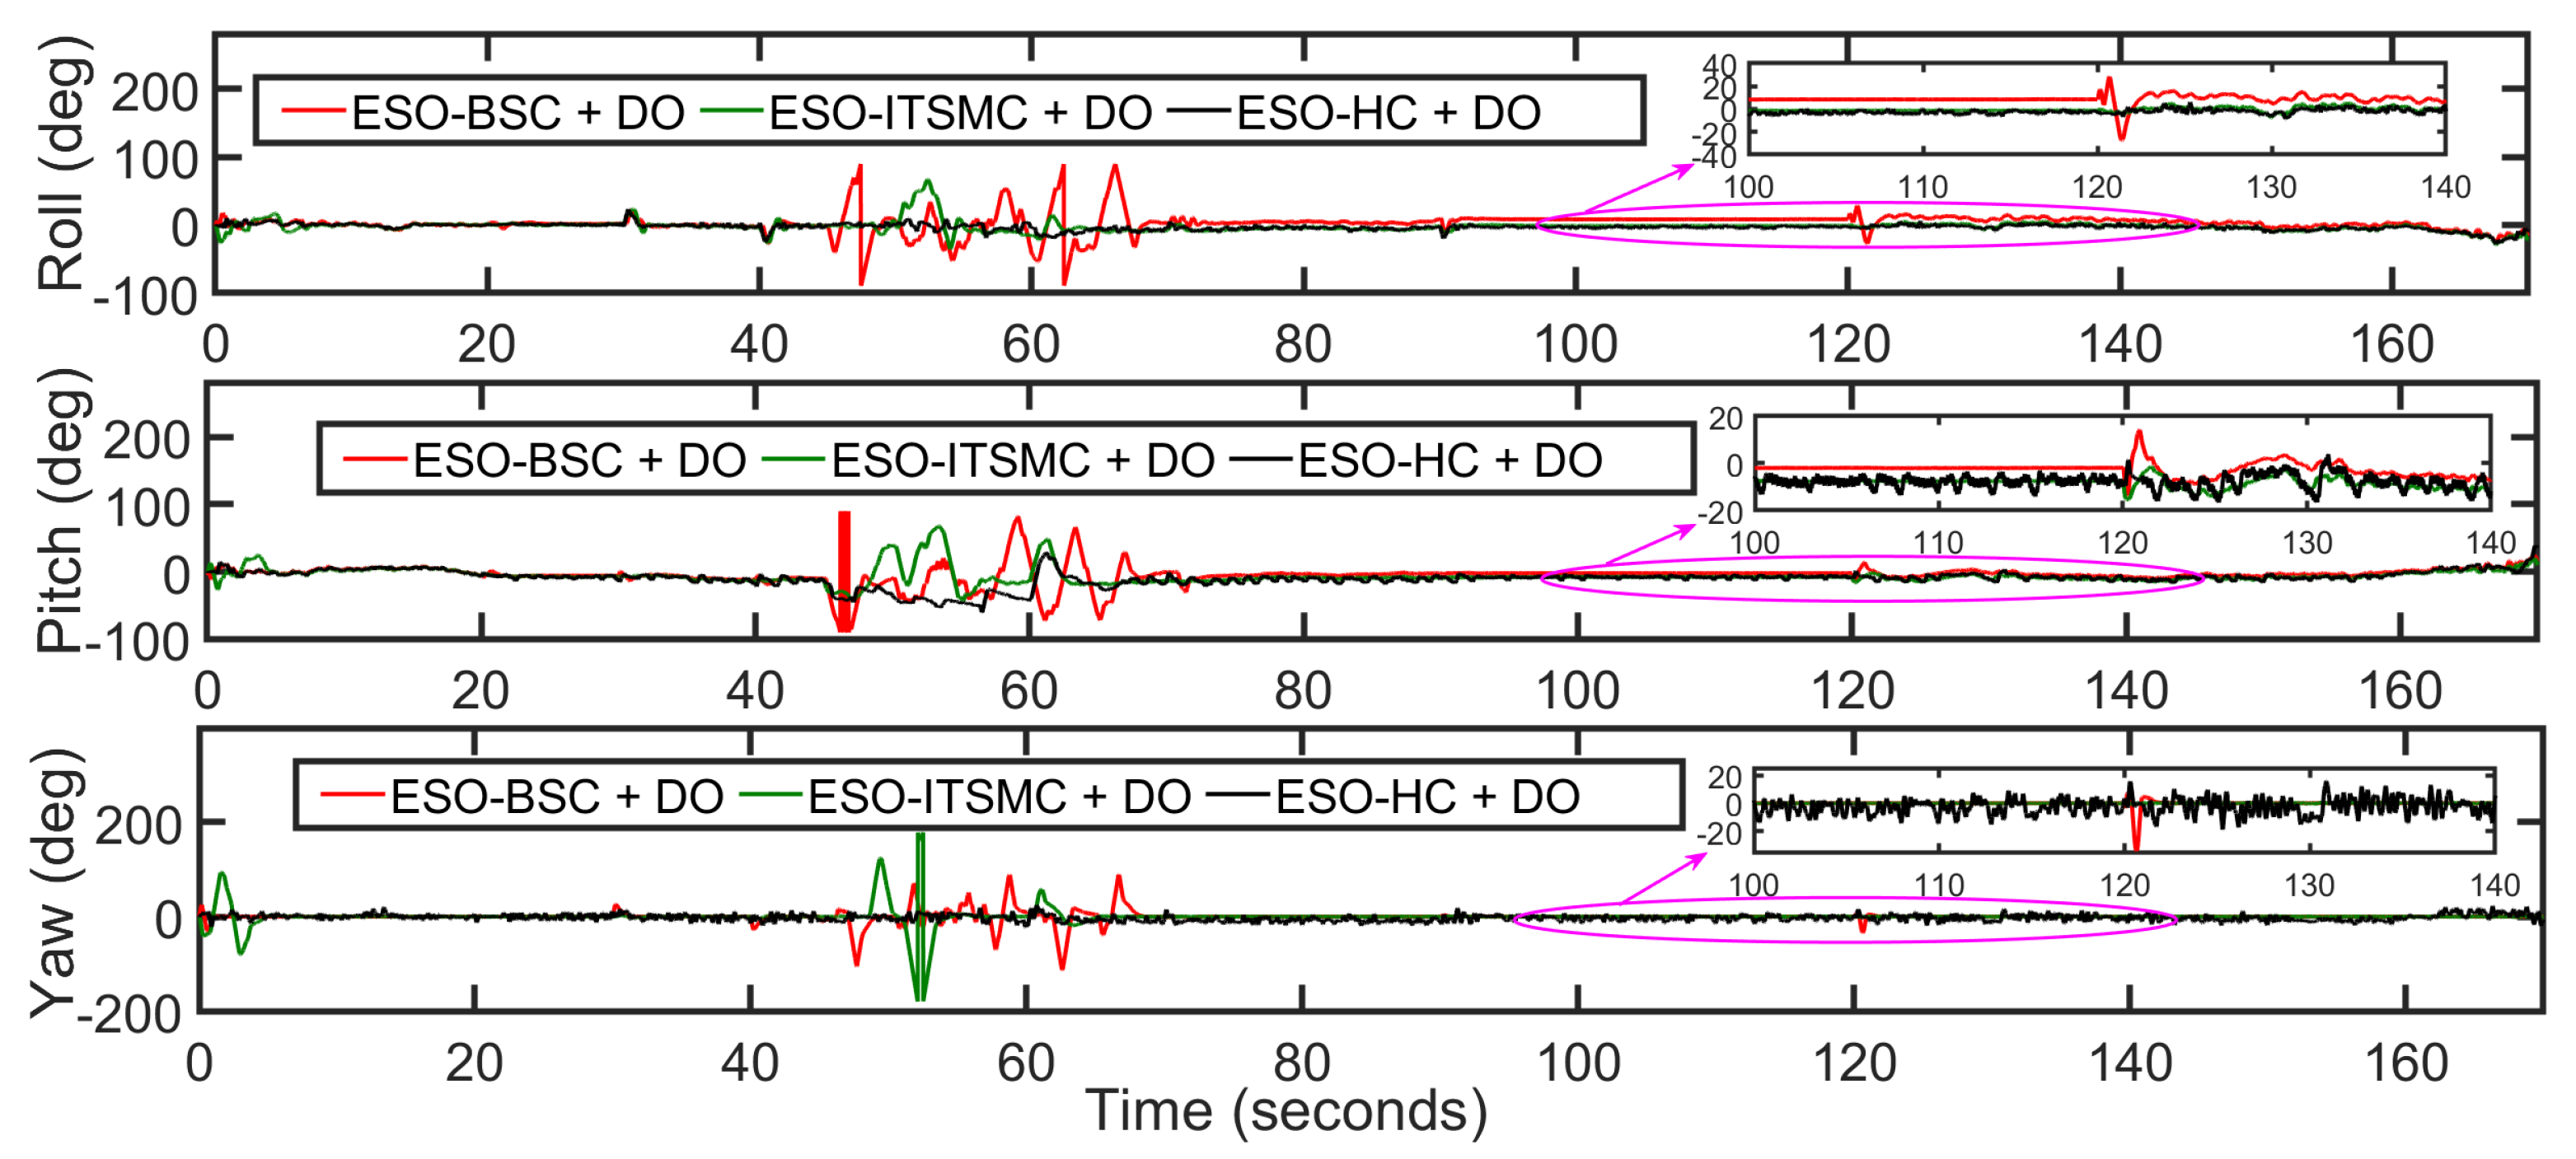
A biplane quadrotor (hybrid vehicle) benefits from rotary-wing and fixed-wing structures. We design a dual observer-based autonomous trajectory tracking controller for the biplane quadrotor. Extended state observer (ESO) is designed for the state estimation, and based on this estimation, a Backstepping controller (BSC), Integral Terminal Sliding Mode Controller (ITSMC), and Hybrid Controller (HC) that is a combination of ITSMC + BSC are designed for the trajectory tracking. Further, a Nonlinear disturbance observer (DO) is designed and combined with ESO based controller to estimate external disturbances. In this simulation study, These ESO-based controllers with and without DO are applied for trajectory tracking, and results are evaluated. An ESO-based Adaptive Backstepping Controller (ABSC) and Adaptive Hybrid controller (AHC) with DO are designed, and performance is evaluated to handle the mass change during the flight despite wind gusts. Simulation results reveal the effectiveness of ESO-based HC with DO compared to ESO-based BSC and ITSMC with DO. Furthermore, an ESO-based AHC with DO is more efficient than an ESO-based ABSC with DO.
Keywords: biplane quadrotor; extended state observer; nonlinear disturbance observer; dual observer; adaptive backstepping controller; integral terminal sliding mode controller; adaptive hybrid controller biplane quadrotor; extended state observer; nonlinear disturbance observer; dual observer; adaptive backstepping controller; integral terminal sliding mode controller; adaptive hybrid controller