1. Introduction
According to data from the World Health Organization, the global population aged 60 and above will increase from 11% to 22% between 2000 and 2050, indicating a continuous intensification of aging worldwide [
1,
2]. Age-related decline in walking ability often accompanies this demographic shift, severely impacting the quality of life for the elderly and posing a significant challenge to global healthcare systems [
3,
4,
5]. Exoskeleton robots, as wearable assistive devices that integrate intelligence, safety, and portability, represent a key technology to address this challenge. Consequently, they have become a focal point of competitive research worldwide [
6,
7,
8,
9].
Based on differences in structure and actuation methods, mainstream research directions can be divided into rigid exoskeletons and flexible exoskeleton suits. The latter utilizes flexible components such as textiles and cables, offering advantages of lightweight design and high compliance, making them suitable for assisting daily activities [
10]. In contrast, the former, with its rigid linkage structure and high output torque capability, holds greater advantages in scenarios requiring strong supportive force, such as rehabilitation training and load-bearing assistance.
The lower-limb exoskeleton robot studied in this paper belongs to a rigid, multivariable, coupled nonlinear system. The accuracy and smoothness of its control performance highly depend on the precision of its dynamic model. Therefore, precisely obtaining its dynamic parameters is a core prerequisite for implementing advanced control strategies such as high-quality model predictive control and impedance control. However, due to factors such as variations in human lower-limb dimensions, exoskeleton assembly errors, operational wear, and complex human–robot interaction, dynamic parameters often exhibit significant uncertainty. This makes the efficient and high-precision identification of dynamic parameters a critical and urgent challenge in this field.
To address this challenge, researchers both domestically and internationally have proposed various parameter identification methods. For example, the CAD-assisted method [
11] is efficient and non-destructive but struggles to account for manufacturing errors and joint friction. The inverse dynamics method based on internal sensors (such as motor encoders and torque sensors) [
12] is susceptible to sensor noise and modeling errors, potentially generating “ghost forces.” Methods relying on external professional equipment like motion capture systems and force plates [
13], while highly accurate, are costly and difficult to deploy outside laboratory settings. Through comprehensive comparison, the linearized global identification method, which linearizes the nonlinear dynamic equations within the parameter space, can retain system coupling relationships and transform the identification problem into a linear regression problem, making it relatively more suitable for engineering applications. However, the linear models generated by this method often suffer from high parameter dimensionality and ill-conditioned properties. Consequently, the solution process itself becomes a complex optimization problem that requires robust and efficient optimization algorithms.
Swarm intelligence optimization algorithms are often employed to solve such complex optimization problems due to their powerful global search capability. Among them, the Grey Wolf Optimizer (GWO) demonstrates promising application potential owing to its simple structure, few parameters, ease of implementation, and its balance between global exploration and local exploitation achieved through an adaptive convergence factor. However, when tackling complex optimization problems characterized by high dimensionality, multimodality, and ill-conditioning—such as exoskeleton dynamic parameter identification—the standard GWO algorithm still reveals inherent shortcomings. These include uneven initialization, slow convergence speed, and a tendency to become trapped in local optima, which limit further improvements in its identification accuracy and efficiency.
To address the issues mentioned above, this paper proposes a dynamics parameter identification method for a two-degree-of-freedom lower-limb exoskeleton based on an improved Grey Wolf Optimizer (Tent-GA-GWO), aiming to achieve high-precision and high-efficiency parameter identification and thereby provide a model foundation for the precise control of the exoskeleton.
The main work and contributions of this paper include: constructing a two-degree-of-freedom dynamic model that incorporates joint friction and linearizing it to obtain a set of linear parameters for identification; systematically improving the GWO algorithm in three aspects—utilizing Tent chaotic mapping to optimize population initialization, designing a nonlinear control parameter strategy to dynamically balance the algorithm’s search behavior, and introducing genetic algorithm selection, crossover, and mutation operators to enhance population diversity, thereby forming the Tent-GA-GWO algorithm; designing a Fourier series-based excitation trajectory that complies with human motion constraints to fully excite the system’s dynamic characteristics; and comprehensively validating the superiority of the proposed algorithm in terms of convergence speed, identification accuracy, and engineering practicality through comparative simulation experiments and physical prototype tests. This research not only provides a high-performance optimization algorithm for solving ill-conditioned linear model parameters but also establishes a theoretical and experimental foundation for the precise modeling and personalized control optimization of lower-limb exoskeleton robots.
2. Dynamic Analysis of a Lower-Limb Exoskeleton Robot
To achieve precise identification of the dynamic parameters of the lower-limb exoskeleton, it is first necessary to establish a reliable mathematical model. This section constructs a two-degree-of-freedom dynamic model that incorporates joint friction and link inertia based on the Lagrangian method. Through linearization, the nonlinear identification problem is transformed into a linear regression problem, laying the foundation for subsequent parameter identification.
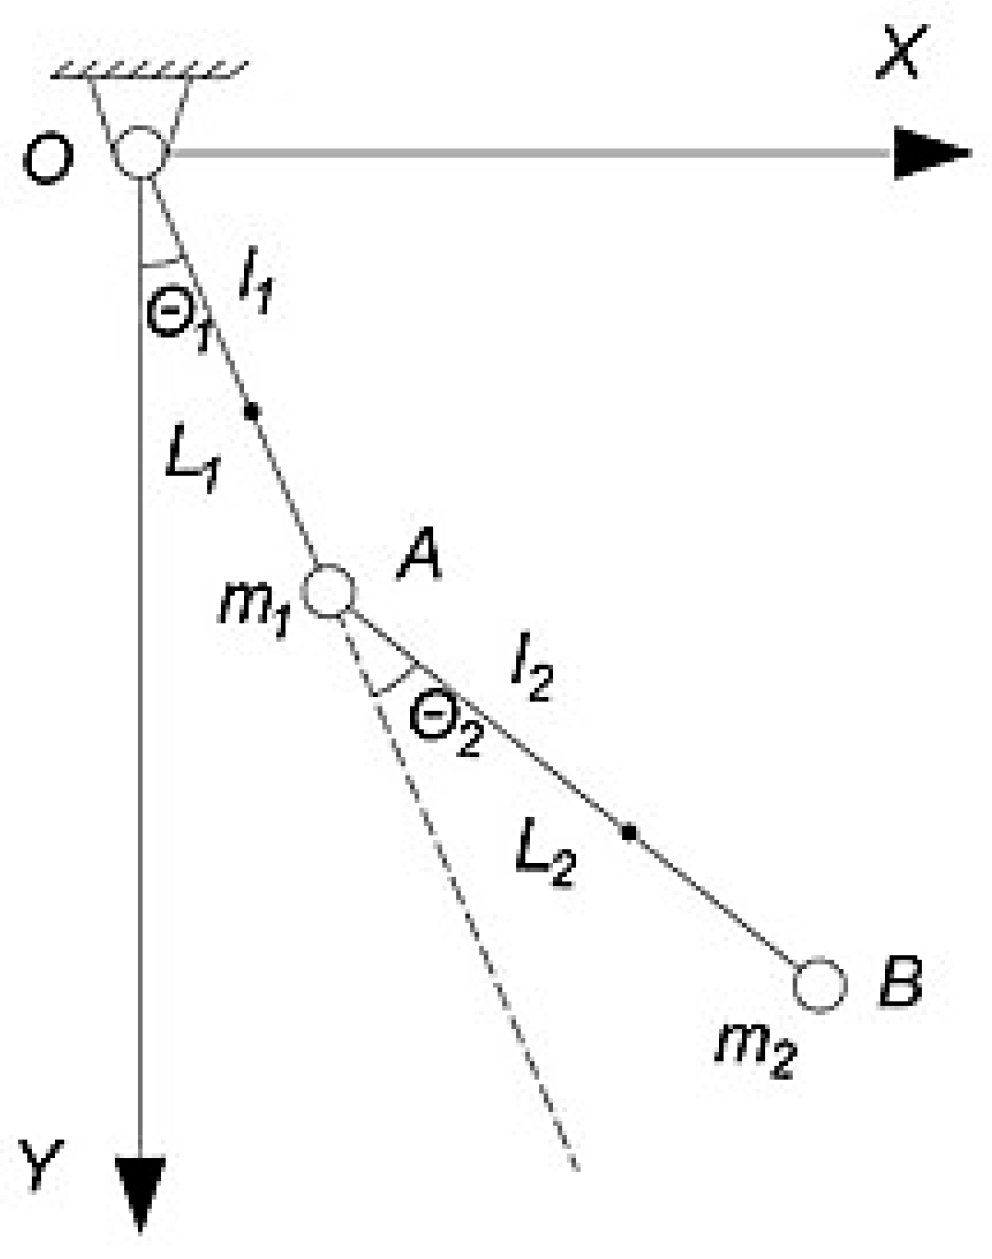
To support the subsequent modeling and parameter identification efforts, this paper simplifies the structure of the two-degree-of-freedom lower-limb exoskeleton robot, representing it equivalently using a linkage structure. The specific simplified form is shown in
Figure 1.
Where the hip joint state variable is defined as the angle between the hip joint and the vertical direction. The knee joint state variable is defined as the angle between the knee joint and the thigh extension. The relevant parameters are described below:
, : Indicate the angle of rotation of the hip and knee joints, respectively (unit: rad).
, : Indicate the distance from the hip and knee joints to the center of gravity of the thigh and calf, respectively (unit: m).
, : Denote thigh length and calf length, respectively (unit: m).
, : Denote the mass of the thigh and the mass of the calf, respectively (unit: kg)
, : Denote the mass moment of inertia of the thigh and the mass moment of inertia of the calf, respectively (unit: kg/m2).
g: Denotes the gravitational acceleration constant 9.8 (unit: m/s).
: Coordinate vectors representing hip and knee joint angle information of the exoskeleton robot.
: Represents the position of the center of mass of the thigh arm in the Cartesian coordinate system.
: Denotes the position of the center of mass of the lower leg arm in the Cartesian coordinate system.
For the simplified two-degree-of-freedom lower-limb exoskeleton robot, its dynamics model is established by Lagrangian method. Considering that the exoskeleton will be affected by friction in the actual operation process, this paper, for the friction modeling, introduces the friction term into the model of the exoskeleton. Among the friction models, Coulomb friction and viscous friction models are chosen. The resulting exoskeleton dynamics model can be expressed as:
Herein, T represents the joint torque vector. denotes the inertia matrix, denotes the Coriolis matrix, denotes the gravitational torque, denotes the friction torque.
As indicated by the parameters in Equation (1), the dynamic model parameters of the lower-limb exoskeleton robot are primarily determined by its physical parameters (such as link lengths, joint weights, moments of inertia, and center-of-mass positions). In practice, obtaining these parameters directly is challenging. Furthermore, in the dynamic model described by Equation (1), the physical parameters and state variables exhibit a high degree of coupling. This coupling relationship can affect both parameter identification and control algorithm design. Therefore, appropriate decoupling methods are required to establish a direct mapping relationship between torque and state variables. Proceeding further, the dynamic equations of the two-degree-of-freedom lower-limb exoskeleton robot are linearized into the following form:
Herein,
denotes the known regression matrix composed of joint angles, angular velocities, and angular accelerations, with a dimension of 2 × 8, and
represents the set of dynamic parameters to be identified, with a dimension of 8 × 1, expressed in the following form:
The linearized Equation (2) serves as the foundation for subsequent parameter identification: the regression matrix Y can be constructed from motion state data, and the input torque T can be measured via sensors, thereby transforming the dynamic parameter identification problem into an optimization problem for solving the parameter vector Φ.
After transforming the nonlinear dynamic model into a linear regression form via Equation (2), the parameter identification problem can be formally treated as a least squares estimation problem. However, directly applying classical methods such as Ordinary Least Squares (OLS) or Recursive Least Squares (RLS) to solve it faces multiple challenges in practical scenarios of lower-limb exoskeleton parameter identification, which are reflected in the following aspects.
First, due to safety constraints in human motion, the excitation trajectory often leads to strong multicollinearity among the column vectors of the regression matrix Y, resulting in a high condition number and ill-conditioned characteristics. In such cases, the least squares solution becomes highly sensitive to measurement noise, where minor data disturbances can cause significant oscillations in the parameter estimates, leading to unstable and unreliable results. Second, the elements in the parameter vector Φ to be identified have clear physical meanings (such as mass, inertia, and friction coefficients) and must satisfy natural constraints like non-negativity or specific value ranges. Classical least squares methods, as unconstrained optimization approaches, cannot incorporate such prior information, potentially yielding physically infeasible identification results (e.g., negative moments of inertia) [
14]. Furthermore, the linearized model is an approximation of a complex nonlinear system, involving unmodeled dynamics (such as link deformation and transmission gaps) and linearization errors, while sensor noise often does not follow a Gaussian distribution. These factors cause the residuals to no longer satisfy the Gaussian white noise assumption required by ordinary least squares, rendering least squares-based estimators suboptimal and biased. Finally, in high-dimensional, ill-conditioned parameter spaces, the loss function may exhibit multiple local minima. Gradient-based methods or analytical least squares solutions are prone to converging to local optima, making it difficult to guarantee a globally optimal solution that closely reflects the true physical parameters [
15].
In summary, the problem of dynamic parameter identification for lower-limb exoskeletons is, in essence, an ill-conditioned global optimization problem characterized by a regression matrix with a high condition number, the need to handle parameter constraints, and the influence of model mismatch and complex noise. Traditional linear algebraic methods have inherent limitations in addressing such problems. Therefore, this paper adopts a swarm intelligence optimization algorithm—which possesses strong global search capability, low sensitivity to initial values, and ease of incorporating constraint-handling mechanisms—as the solution framework. The subsequently proposed Tent-GA-GWO algorithm is precisely designed to overcome the aforementioned challenges and achieve robust, high-precision parameter identification in complex environments.
3. The Grey Wolf Optimizer (GWO)
The performance of the optimization algorithm directly affects the accuracy and efficiency of parameter identification. This section will introduce the fundamental principles, mathematical model, and the mechanisms of GWO for balancing global exploration and local exploitation, while also analyzing its inherent limitations in solving complex optimization problems.
The Grey Wolf Optimizer (GWO) is a swarm intelligence optimization algorithm proposed by Mirjalili et al. from Griffith University in Australia [
16]. This algorithm is an optimization search method developed based on inspiration drawn from the predatory activities of grey wolves. Since its introduction, due to its simple structure, few parameters, ease of implementation, and inherent balance mechanism between global exploration and local exploitation, GWO has become one of the classic and efficient swarm intelligence algorithms for solving complex optimization problems. To this day, it continues to be widely applied across various engineering fields and demonstrates strong performance [
17,
18,
19,
20].
The algorithm regards the best, second-best, and third-best individuals in the population as the leader wolves α, β, and δ, respectively. These leaders guide the entire population (ω wolves) to move toward the region of the potential optimal solution, effectively encircling the prey. The core mathematical model for updating their positions is as follows:
Herein, denotes the current iteration number; and are cooperative coefficient vectors; represents the position vector of the prey; represents the position vector of the current grey wolf. During the entire process, a linearly decreases from 2 to 0, and and are random numbers in the interval [0, 1].
Subsequently,
α, β, and
δ lead the search to locate the optimal solution (prey). The mathematical model for individual wolves tracking the prey is as follows:
In this formula,
represent the distances between the
wolves and other individuals, respectively;
denote the current positions of the
wolves, respectively;
are random vectors calculated by Equations (8) and (9);
X is the position of the current grey wolf.
Meanwhile, Equations (11)–(13), respectively, define the step size and direction for an individual to move toward the wolves, while the final position of the individual is defined by Equation (14).
The distance control parameter a linearly decreases from 2 to 0. As calculated by Equation (5), the corresponding range of A is [−a, a]. At this stage, the wolves perform the attack operation on the prey, meaning the next position of the wolf pack lies between the current position and the prey’s position. When |A| < 1, the wolf pack attacks the prey; however, this situation is prone to falling into local optima. Conversely, when |A| > 1, the wolf pack disperses from the prey, attempting to search for more suitable prey and thereby explore the global optimum.
Despite its aforementioned advantages, the standard GWO framework still exhibits inherent shortcomings when applied to the complex optimization problem of dynamic parameter identification for lower-limb exoskeletons, which is characterized by high dimensionality, ill-conditioning, and multimodality. First, the algorithm’s performance heavily depends on the distribution of the initial population within the parameter space. The random initialization method used in standard GWO may fail to ensure the uniformity and representativeness of initial solutions in high-dimensional and sensitive regions of the solution space, particularly due to the ill-conditioned regression matrix, thereby affecting the stability of subsequent searches and the accuracy of final convergence.
Second, the core parameter controlling the balance between global exploration and local exploitation in the standard algorithm—the convergence factor a—follows a linear decreasing strategy from 2 to 0. Although simple, this strategy struggles to precisely adapt to the complex nonlinear search dynamics involved in the parameter identification of exoskeleton dynamics. Linear decay may lead to insufficient global exploration in the early iterations or a failure to timely intensify local fine search in later stages, hindering the efficient and accurate approach to the globally optimal parameter set.
More critically, GWO’s position update mechanism heavily relies on the information of the α, β, and δ individuals in the current iteration. As iterations proceed, population diversity rapidly diminishes due to the continuous convergence toward a few elite individuals. When addressing parameter identification problems with multiple local optima, this mechanism is highly prone to causing premature convergence to a local optimum, thereby losing the ability to discover a globally superior parameter configuration. This directly limits the final accuracy of the identification results.
Consequently, the limitations of the standard GWO algorithm in the aforementioned aspects constrain its direct effectiveness in high-precision parameter identification tasks for exoskeletons. Targeted improvement of these shortcomings is clearly necessary to enhance the robustness, convergence speed, and ultimate accuracy of parameter identification.
4. Tent-GA-GWO
To address the inherent limitations of the standard GWO algorithm in exoskeleton parameter identification, as analyzed in
Section 3, this paper proposes the Tent-GA-GWO algorithm, whose improvement mechanisms are driven by a clear problem-oriented approach. Specifically, to tackle the sensitivity to initial values caused by the ill-conditioned regression matrix, Tent chaotic mapping with superior ergodicity is employed for population initialization. To better match the characteristics of exoskeleton systems—where parameters are strongly coupled and the search dynamics are complex—a nonlinear convergence factor adjustment strategy based on a quadratic function is designed. Furthermore, to overcome the algorithm’s tendency for premature convergence and susceptibility to local optima, selection, crossover, and mutation operators from the genetic algorithm are introduced to enhance population diversity. These three synergistic improvements together form a targeted hierarchical optimization framework. The implementation details of each improvement are elaborated in the following sections.
4.1. Initialization Using Tent Chaotic Mapping
Chaotic motion is characterized by randomness, regularity, and ergodicity. These properties enable algorithms to more easily escape local optima when solving function optimization problems, thereby helping to maintain population diversity and enhance global search capabilities. Existing chaotic mappings include the Tent mapping, Logistic mapping, among others. However, different chaotic mappings vary in their ability to improve function optimization. The Logistic mapping exhibits a higher probability of generating values within the intervals [0, 0.1] and [0.9, 1]. Consequently, the non-uniform traversal of the Logistic mapping tends to slow down the convergence speed of the algorithm, thereby reducing its efficiency. Shan et al. [
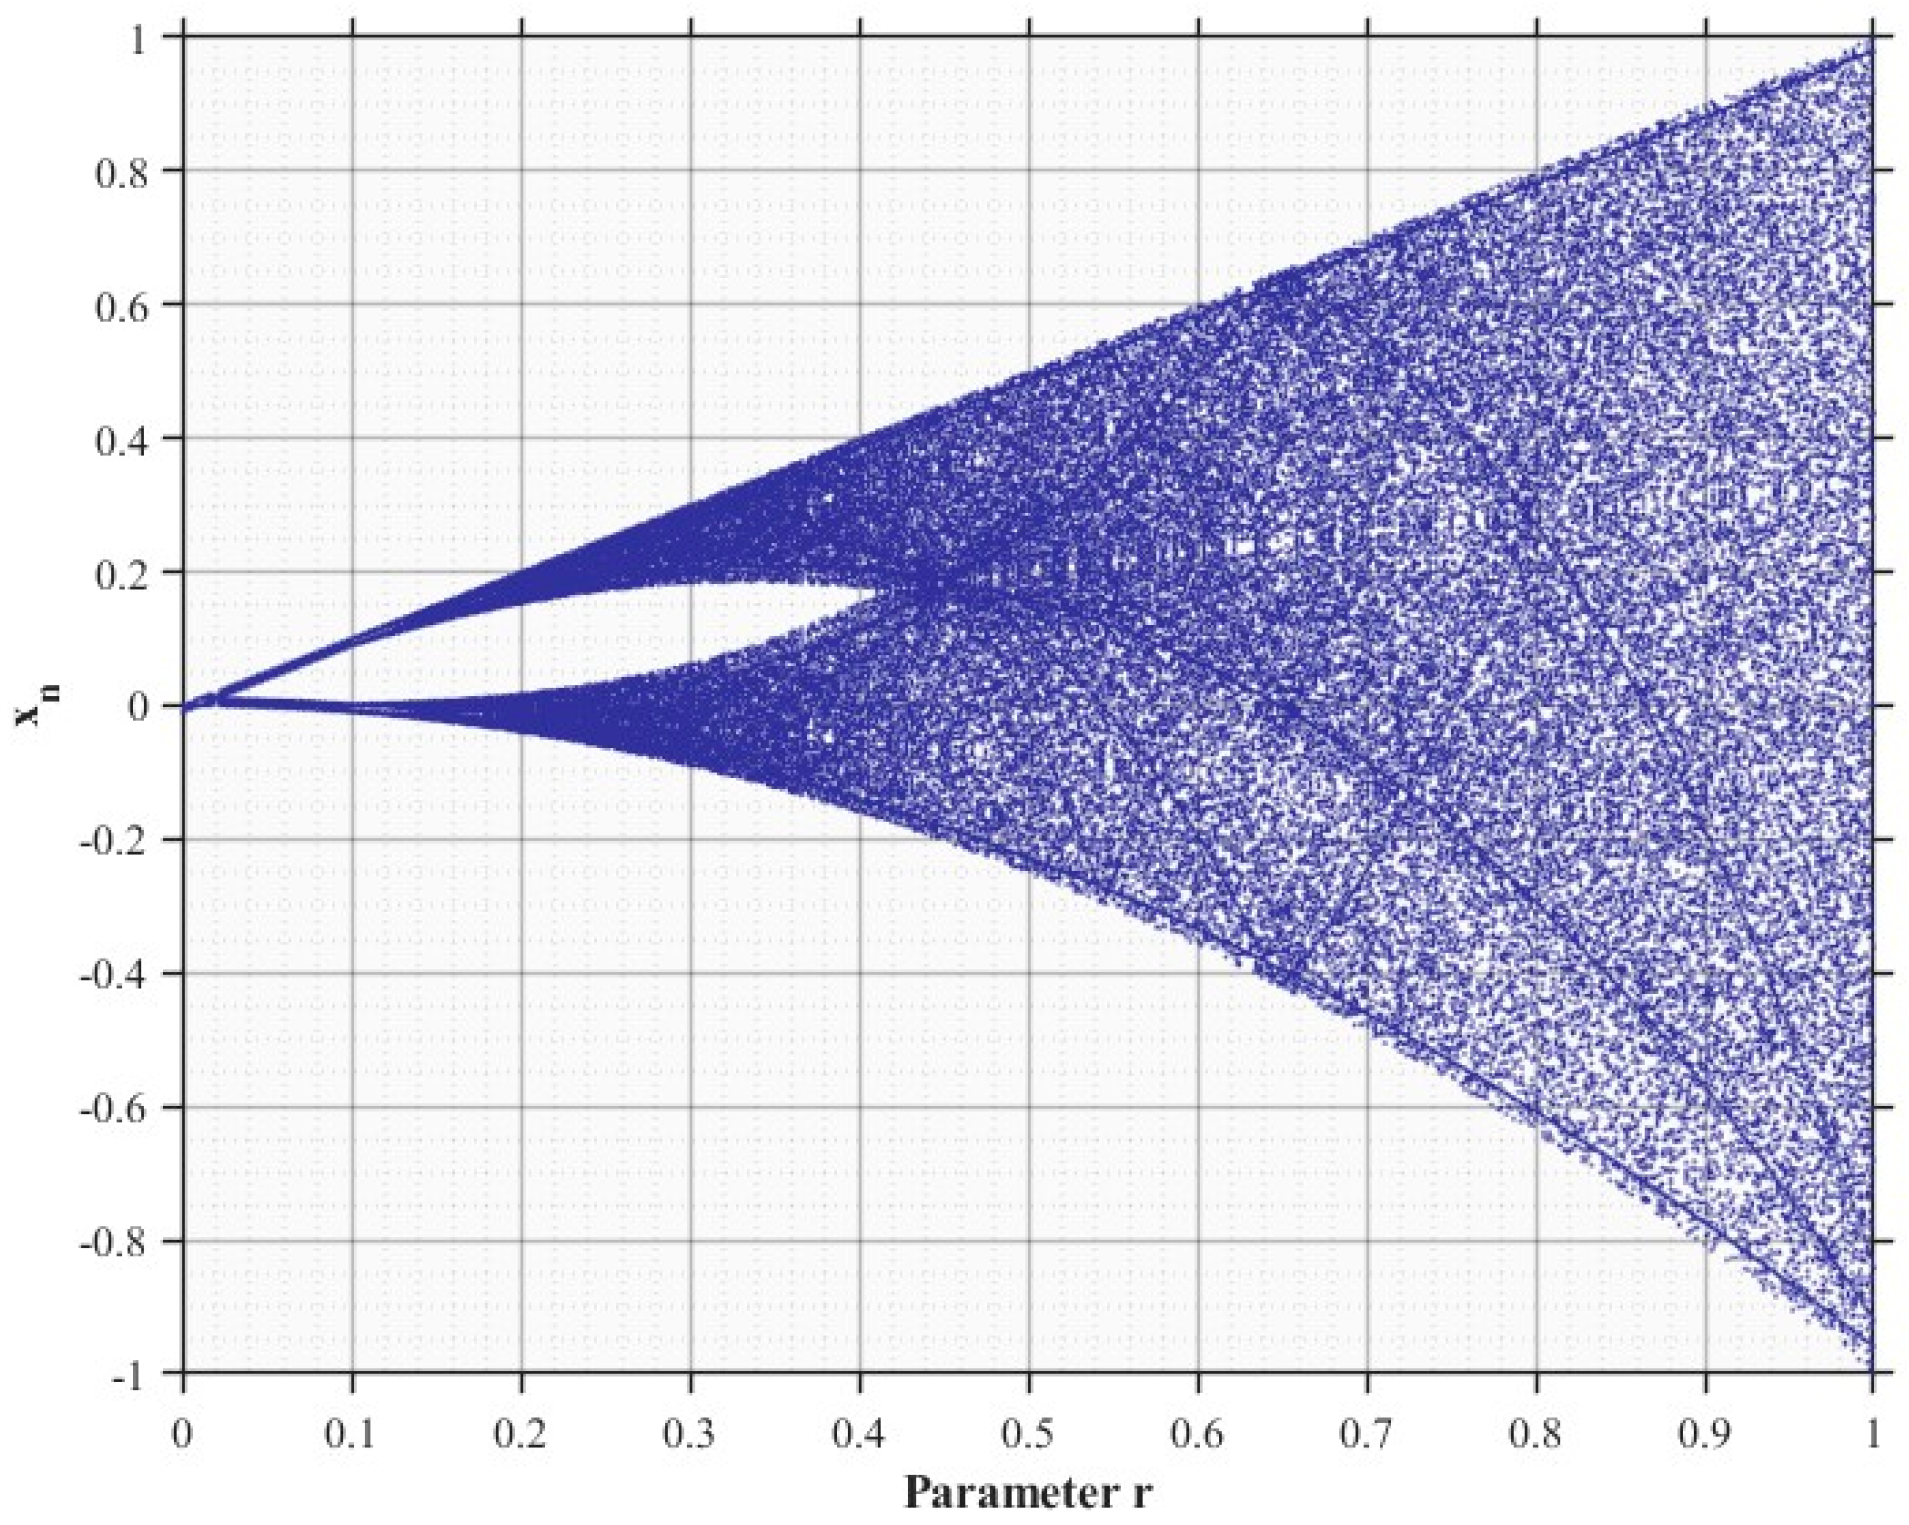
21], using topological conjugacy theory, demonstrated that the Tent mapping possesses better ergodic uniformity than the Logistic mapping, can accelerate the optimization process, and simultaneously generates initial values that are more uniformly distributed within [0, 1]. For the lower-limb exoskeleton dynamic parameter identification problem studied in this paper, the regression matrix often exhibits ill-conditioned properties, with a sensitive parameter space containing multiple local optima. The superior ergodic uniformity of the Tent mapping helps to widely and uniformly distribute the initial population across the high-dimensional parameter space in the early stage, laying the foundation for the algorithm’s subsequent global search within the ill-conditioned and multimodal space. This, in turn, increases the likelihood of accurately capturing the true dynamic parameters. To visually demonstrate this key mathematical characteristic of the Tent mapping’s ergodic uniformity, its bifurcation diagram is shown in
Figure 2. Therefore, this paper utilizes Tent mapping to initialize the population.
Tent chaotic mapping, also known as tent mapping due to its function’s resemblance to a tent shape, is expressed as follows:
The specific steps for generating sequence values using the Tent chaotic map are as follows:
Step 1: Randomly generate an initial value (within [0, 1], and avoid being in {0.2, 0.4, 0.6, 0.8}), and record it in the marker group, i.e., , , .
Step 2: Generate an x-sequence iteratively according to Equation (15), and set .
Step 3: If the maximum number of iterations is reached, proceed to Step 4. Else, if or (where ), adjust the initial iteration value according to (where is a random number), and set . Else, return to Step 2.
Step 4: Terminate the operation and retain the x-sequence.
4.2. Nonlinear Control Parameter Strategy
In the standard grey wolf optimization algorithm, the convergence behavior is dominated by the control parameter
, and its absolute value directly determines the search step size of the algorithm. In order to achieve the balance between global exploration and local development, the adjustment strategy of parameter
is designed to take a larger value at the initial stage of iteration to enhance the global exploration ability of the algorithm and avoid falling into local optimization; At the later stage of the iteration, the smaller value is taken to strengthen the fine search of the local area, so as to accelerate the convergence. This strategy is implemented by a linearly decreasing convergence factor a, as shown in Equation (16), and the adjustment strategy of a is usually a linear reduction from 2 to 0.
However, the linear decreasing strategy of the control parameter a in the standard GWO is overly idealized and struggles to precisely match the complex nonlinear dynamics of the actual search process. Specifically, for the exoskeleton dynamic parameter identification problem addressed in this paper, strong coupling exists among parameters such as inertia and Coriolis forces, resulting in an exceptionally complex loss function surface with multiple extreme regions. To more closely simulate this process, this paper proposes a nonlinear adjustment strategy based on a quadratic function, as shown in Equation (17). This strategy allows the value of a to decrease slowly in the early iterations to maintain sufficient global exploration, enabling a “coarse adjustment” across the complex parameter space. In the later iterations, it accelerates the decay, prompting the algorithm to rapidly transition into local exploitation for a “fine adjustment” of key parameters. This mechanism can more adaptively align with the nonlinear search dynamics of the exoskeleton system, achieving a more efficient balance between the exploration and exploitation phases.
In the formula, and represent the initial value and final value of a, respectively, t denotes the current iteration number, and denotes the maximum number of iterations.
At the same time, in order to verify the advantages of the nonlinear adjustment strategy of the quadratic function proposed in this paper, several existing nonlinear parameter adjustment strategies are selected for comparison. The parameter formula [
22,
23] is shown in the following formula, where
is the nonlinear adjustment coefficient.
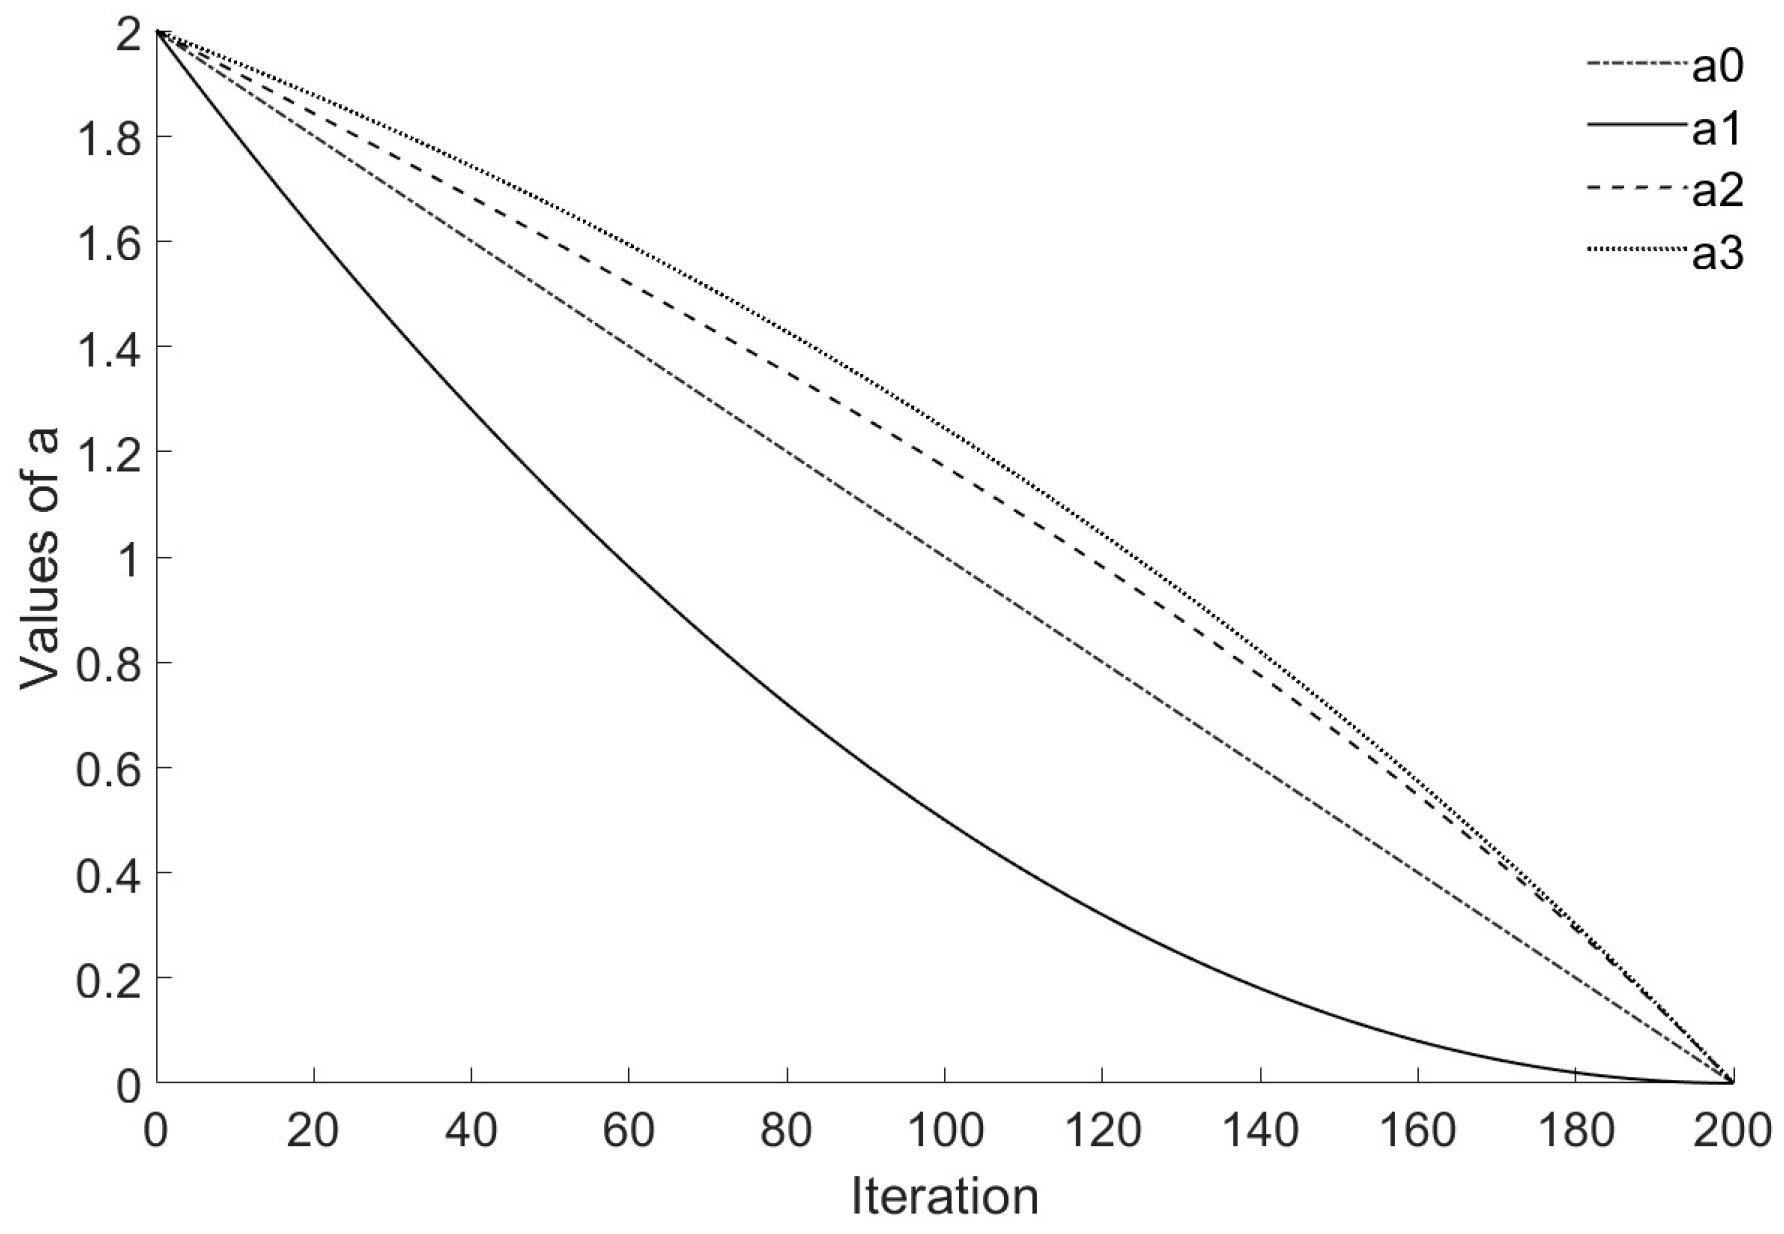
Through simulation analysis (as shown in
Figure 3), it can be seen that the exploration and development stages after the optimization of nonlinear control parameters account for 29.3% and 70.7%, respectively, which balances the local development and global search capabilities of the algorithm and improves the convergence speed of the algorithm. Through the comparison of the four control parameters, we can see that the control parameters proposed in this paper can balance the local search and global search capabilities more effectively than the other three non-linear control parameters.
4.3. Incorporation of Genetic Algorithm
The identification of exoskeleton dynamic parameters is essentially a high-dimensional, ill-conditioned multimodal optimization problem, where multiple local optima exist in the solution space. Although the standard GWO algorithm possesses good local exploitation capability, its update mechanism overly relies on the current elite individuals (α, β, and δ wolves), which can easily lead to rapid loss of population diversity in later iterations. Consequently, the algorithm may become trapped in local optima, making it difficult to locate the globally optimal parameter set. To address this issue, this paper deliberately incorporates the evolutionary mechanism of the Genetic Algorithm (GA). By integrating its selection, crossover, and mutation operators, the proposed approach retains GWO’s advantage of rapid convergence while significantly enhancing population diversity and global exploration capability. This systematically suppresses premature convergence and improves the algorithm’s robustness and identification accuracy in multimodal spaces.
The selection operation is employed to conduct guided screening of the population after each generation’s position update. Different from the traditional roulette wheel selection, this paper adopts an elite retention strategy based on ranking: individuals in the population are sorted by fitness, the top 3/4 of individuals with better fitness are retained, and the individual with the best fitness in the current generation is duplicated to directly replace the bottom 1/4 of individuals with the worst fitness. This strategy accelerates the propagation of superior genetic information, thereby effectively improving the algorithm’s convergence efficiency.
The introduction timing of crossover and mutation operations is specially designed. To prevent the loss of high-quality genes due to random crossover in the early iterations, this paper restricts crossover and mutation operations to be performed only after the algorithm enters the local exploitation phase (i.e., when < 1). At this stage, the population quality has been preliminarily improved, and performing crossover operations facilitates exploration around promising solutions. Single-point crossover is adopted with a probability set to Pc = 0.6, while basic bit mutation is employed with a probability set to Pm = 0.05.
For the mutation operation, a competition-based selection mechanism is further introduced to control blind randomness: the individual before mutation is regarded as the parent, and a child is generated after mutation. The fitness of both is then compared, and only the individual with better fitness is retained for the next generation population. This mechanism ensures that the mutation operation is more likely to lead to performance improvement.
Through the directional concentration enabled by the selection operator, the targeted exploration of the crossover operator, and the controlled perturbation of the mutation operator, the improved algorithm significantly enhances global exploration capabilities while inheriting the strong local exploitation ability of GWO. This provides a more robust optimization framework for solving ill-conditioned, multimodal parameter identification problems.
4.4. Tent-GA-GWO Algorithm Implementation
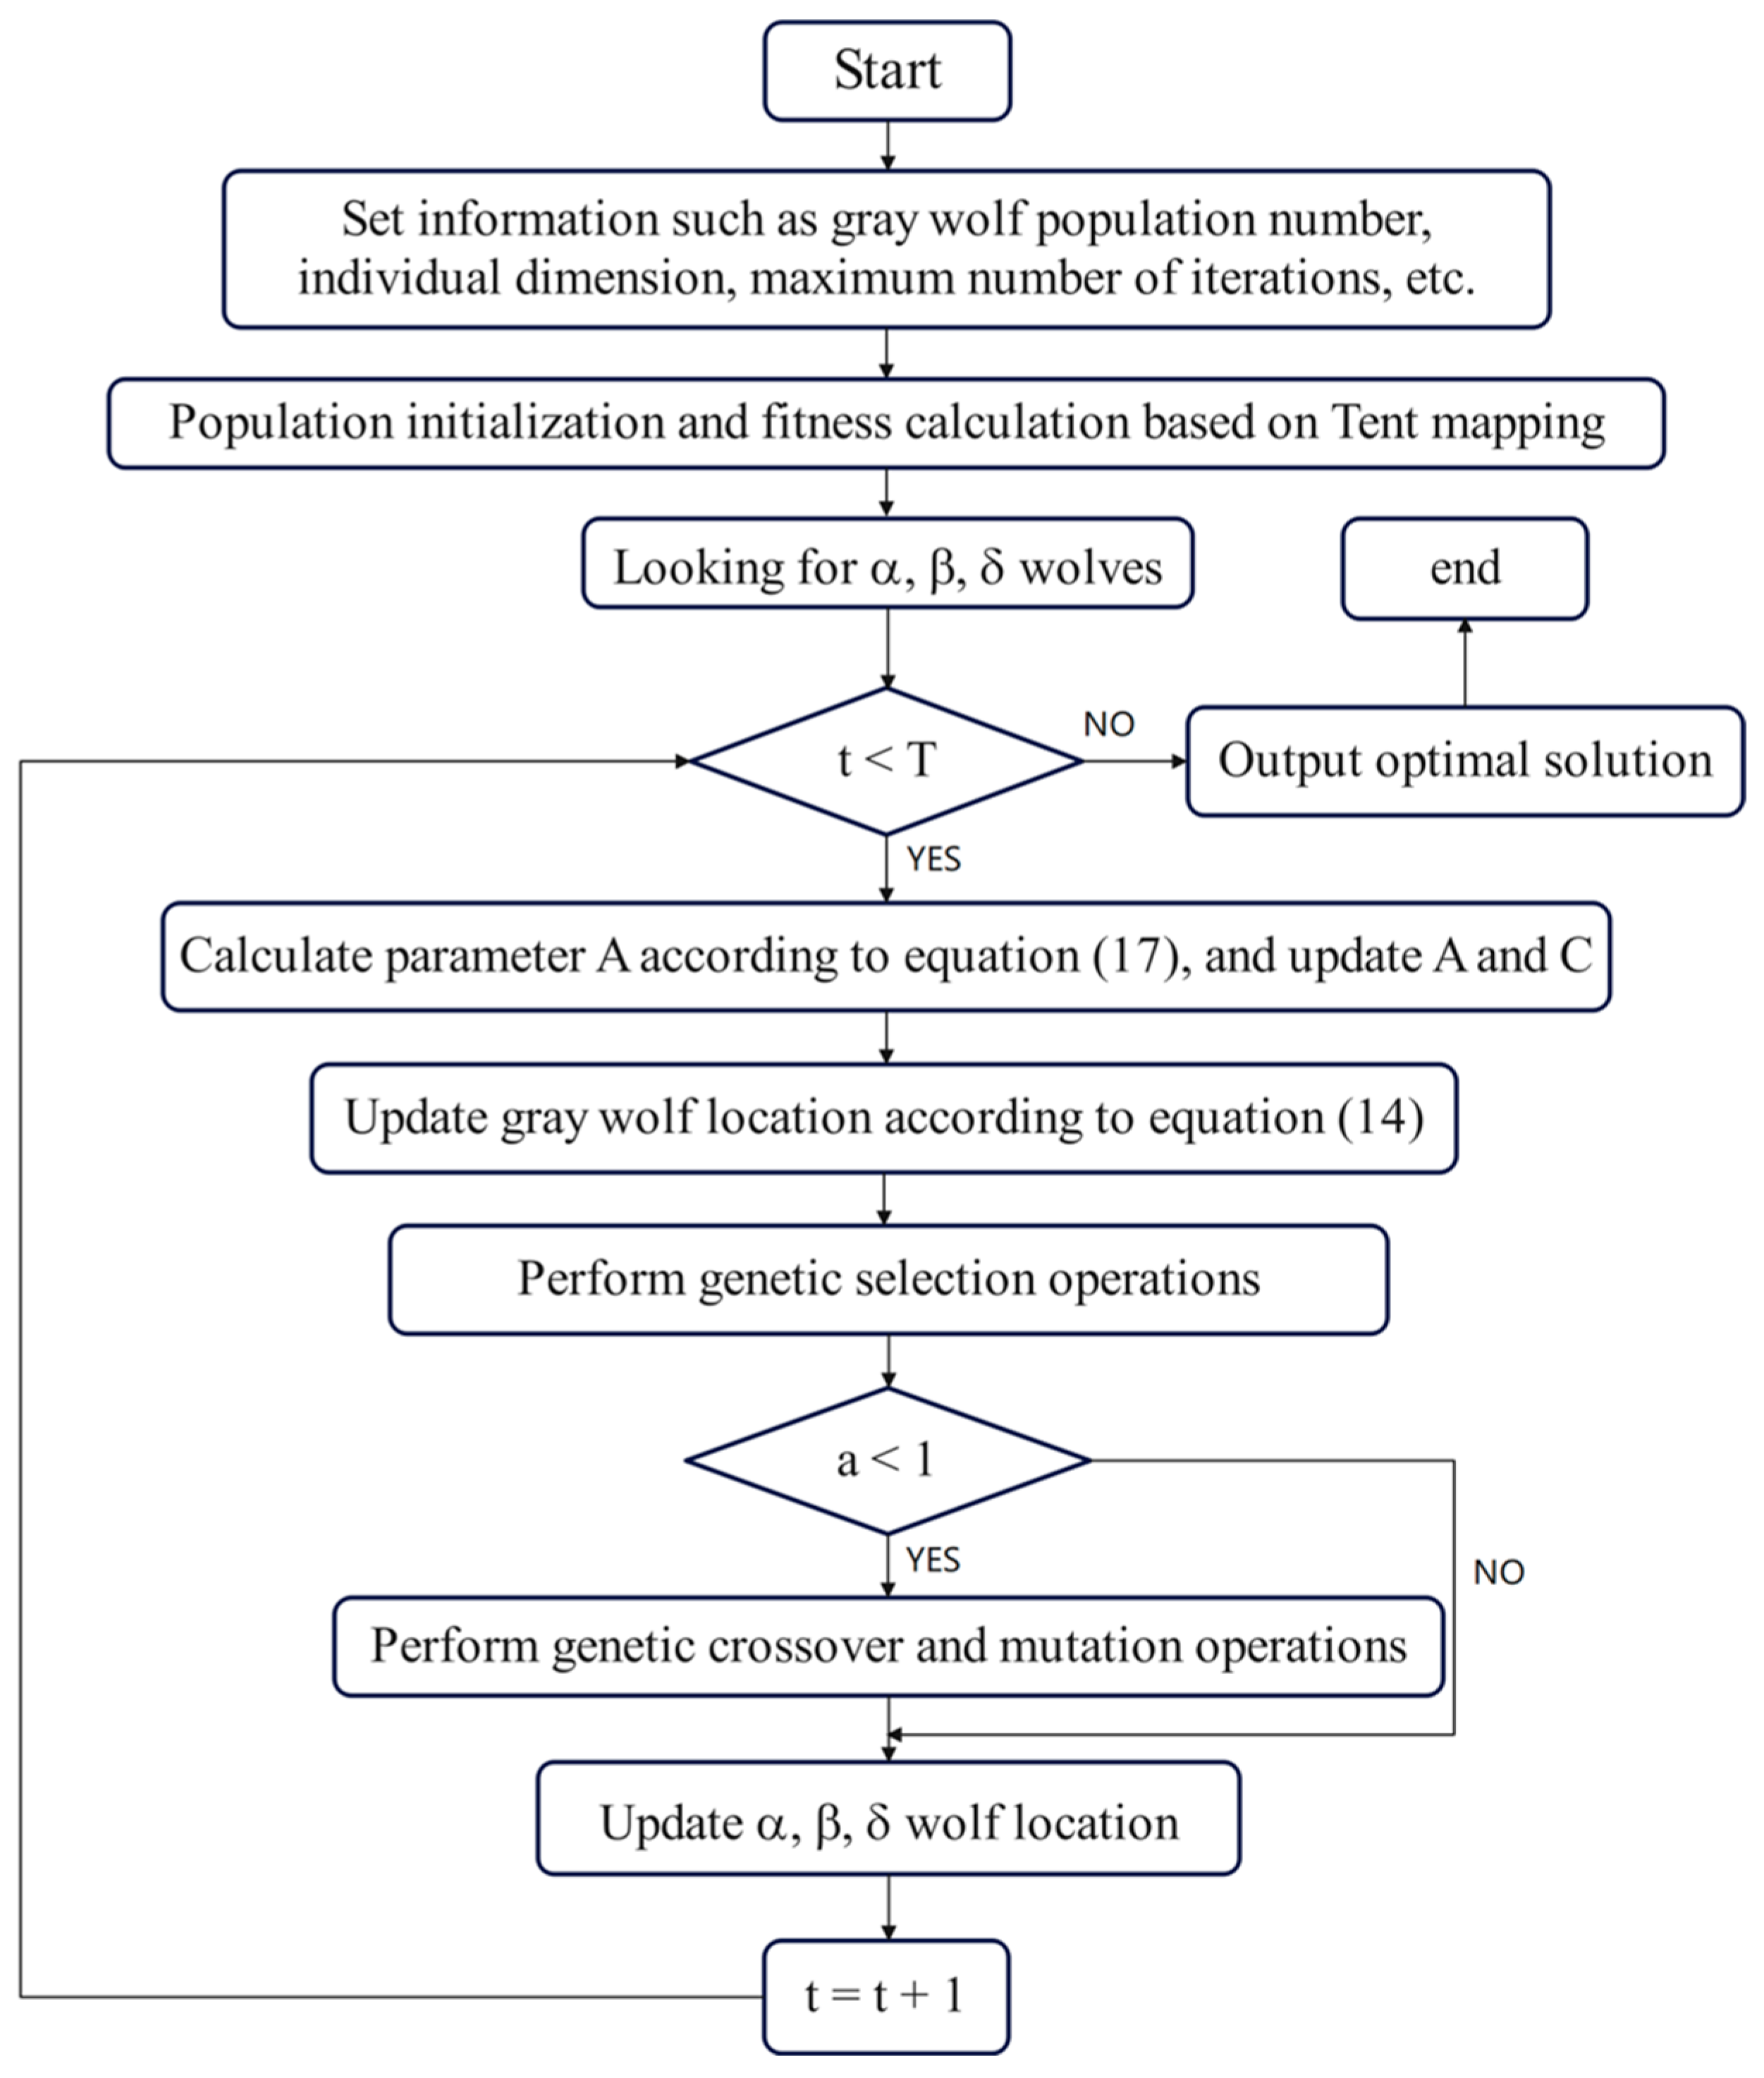
In summary,
Figure 4 shows the detailed flowchart of the Tent-GA-GWO algorithm implementation, where
L represents the population size;
D denotes the parameter dimension;
T is the maximum number of iterations;
Pc is the crossover probability;
Pm is the mutation probability;
a is the convergence factor; and
A and
C are the coefficient vectors:
The specific steps of the Tent-GA-GWO algorithm (Algorithm 1) are as follows:
Step 1: Setting Tent-GA-GWO algorithm parameters and initializing particle swarm. Set population number L = 200, dimension D = 8 and maximum iteration number T = 100, and initialize the particle swarm with Tent chaotic map, among these, the population size L = 200 and the maximum number of iterations T = 100 were determined through pre-experimental tuning to ensure convergence accuracy while improving computational efficiency.
Step 2: Calculate the initial population fitness, and select wolves according to the fitness.
Step 3: Calculating control parameters according to Formula (17), and updating the population position according to Formula (14).
Step 4: Calculate the fitness of the population, and replace the individual with the best fitness with the 1/4 population with the worst fitness.
Step 5: Judging whether the algorithm enters the local development stage according to the control parameters. If, it means that the algorithm has entered the development stage, and the genetic crossover and mutation operations are carried out on the population, and the crossover probability and mutation probability are selected to be 0.6 and 0.05, respectively.
Step 6: calculating fitness according to the population obtained in step 5, and updating wolves.
Step 7: Determine whether the maximum iteration number is reached, if the maximum iteration number is not reached, return to Step 3 to continue iteration, and if the maximum iteration number is reached, the execution is terminated.
Step 8: The iterative algorithm is completed, the position and fitness of
wolf are returned, and the solution is completed.
| Algorithm 1 Tent-GA-GWO algorithm pseudo-code |
Inputs: population number L = 200, population dimension D = 8, maximum iteration number T = 100, crossover probability c = 0.6, mutation probability = 0.05
Output: optimal solution
Algorithm Description:
1: for i = 1: L
2: for j = 1: D
3: Generate initial particle components using the Tent chaotic map in Equation (14)
4: end
5: end // Complete the initialization of particle swarm via Tent chaos, and select α, β, δ wolves
6: for t = 1: T // Iteration loop
7: Calculate the control parameter a, and update the positions of all population individuals according to Equation (13)
8: Calculate the fitness, and replace the worst L/4 individuals with the optimal L/4 individuals
9: if a < 1 then // Local exploitation phase
10: Perform genetic crossover (Pc = 0.6) and mutation (Pm = 0.05) operations on the population
11: end
12: Update the fitness, and reselect α, β, δ wolves
13: end // End of iteration
14: Output the position and fitness of the α wolf |
5. Simulation of Exoskeleton Dynamic Parameter Identification
To validate the effectiveness of the Tent-GA-GWO algorithm in parameter identification, this section first designs an excitation trajectory that conforms to human motion constraints. Subsequently, the identification performance of four algorithms—GWO, GA, LIL-GWO, and Tent-GA-GWO—is compared in a simulation environment. A comprehensive analysis is conducted in terms of convergence speed, fitness value, and parameter accuracy.
5.1. Simulation and Verification of Parameter Identification
To verify the effectiveness of the improvement strategies for the Grey Wolf Optimizer (GWO), simulations for unknown parameter identification were performed on the established two-degree-of-freedom lower limb exoskeleton robot system. The set of model parameters
to be identified is consistent with the definition in
Section 2. As analyzed previously, the dynamic model of the two-degree-of-freedom exoskeleton robot is given by the following equation:
During the parameter identification process, the Mean Squared Error (MSE) was selected as the fitness function for the Grey Wolf Optimizer (GWO), and the set of model parameter vectors from the two-degree-of-freedom exoskeleton robot model was chosen as the target for identification. That is:
The vector set obtained from parameter identification is denoted by
.
Substituting the vector set obtained from parameter identification into Equation (22) yields the calculated torque:
Herein,
denotes the sample size used in parameter identification;
represents the calculated torque obtained by substituting the
-th population individual into the dynamic model Formula (23);
denotes the actual driving torque applied to the 2-degree-of-freedom lower limb exoskeleton robot by the controller when the robot generates motion;
stands for the actual exoskeleton dynamic parameter vector set of the exoskeleton robot;
represents the exoskeleton dynamic parameter vector set obtained via parameter identification;
is the regression matrix, composed of the angle, angular velocity, and angular acceleration of the exoskeleton robot. To achieve parameter identification, a closed-loop simulation system was constructed in the MATLAB/Simulink R2024b environment (MathWorks Inc., Natick, MA, USA) environment for this study. The system uses a Fourier series-based excitation trajectory as the desired input, drives the two-degree-of-freedom exoskeleton dynamic model through a PID controller [
24], and collects real-time data on joint angles, angular velocities, angular accelerations, as well as the actual torque output by the controller. This process generates the regression matrix Y and the torque vector T for parameter identification.
5.2. Excitation Trajectory Design
Prior to conducting simulation experiments for the dynamic parameter identification of the exoskeleton robot, it is necessary to design an excitation trajectory to serve as the desired trajectory for the exoskeleton. In the study of parameter identification for the two-degree-of-freedom exoskeleton robot, the design of the excitation trajectory plays a crucial and non-negligible role. From the perspective of dynamic characteristics, the two joints of the exoskeleton possess distinct dynamic parameters, such as moment of inertia, damping coefficients, and coupling parameters between joints. By designing a rational excitation trajectory and applying excitation signals with specific frequencies, amplitudes, and timing characteristics to each joint, the dynamic responses of the joints can be effectively stimulated. These excitation signals drive the joints to operate under various motion conditions, thereby yielding rich response data, including joint torque, angle, and angular velocity. Through in-depth analysis of this data and the application of system identification algorithms, the dynamic parameters of each joint can be accurately determined, leading to the construction of a highly precise dynamic model for the robotic arm. Considering the uncertainty associated with the excitation trajectory, this paper employs the form of a Fourier series to represent it, as follows:
Herein, denotes the joint offset; , and represent the desired trajectory angle, angular velocity, and angular acceleration of the exoskeleton robot, respectively; , stand for the coefficients of the Fourier series; denotes the fundamental frequency; and represents the period of the Fourier series.
When designing the excitation trajectory, it is noted that the exoskeleton robot serves as a wearable human–machine integrated device. Given the physiological constraints on the range of motion of the human lower limbs, it is imperative to confine the joint angle, angular velocity, and angular acceleration within reasonable human motion limits during the design process. This ensures that the exoskeleton’s movement does not cause secondary injury to the patient [
25]. References [
26,
27,
28] provide detailed discussions on the safe parameter thresholds for lower limb exoskeleton joint motions. Consequently, the constraints for the motion states of the 2-DOF lower limb exoskeleton robot are established, as shown in
Table 1.
To design (or derive) the excitation trajectory, the condition number of the regression matrix is used as the fitness function during the design process. That is:
In the excitation trajectory, , . Since a 5th-order Fourier series is adopted, the number of parameters to be designed for the excitation trajectory is 20.
To obtain an effective excitation trajectory, the Grey Wolf Optimizer (GWO) was employed to iteratively optimize the trajectory parameters. The algorithm’s population size and maximum number of iterations were set to 200 and 100, respectively. The set of parameters yielding the best fitness was selected as the final design for the excitation trajectory. The joint offsets for the thigh and shank trajectories were set to 0.617 and 20.8727, respectively. The 20 Fourier series coefficients to be designed were constrained within the range [−15, 15]. This range was determined based on human joint motion constraints (
Table 1) and multiple trajectory optimization experiments, aiming to generate a trajectory that is both safe and capable of sufficiently exciting the system dynamics.
The optimized Fourier series coefficients obtained from the design process are presented in the table below, where and represent the coefficients of the k-th order sine and cosine terms, respectively.
Substituting the coefficients from
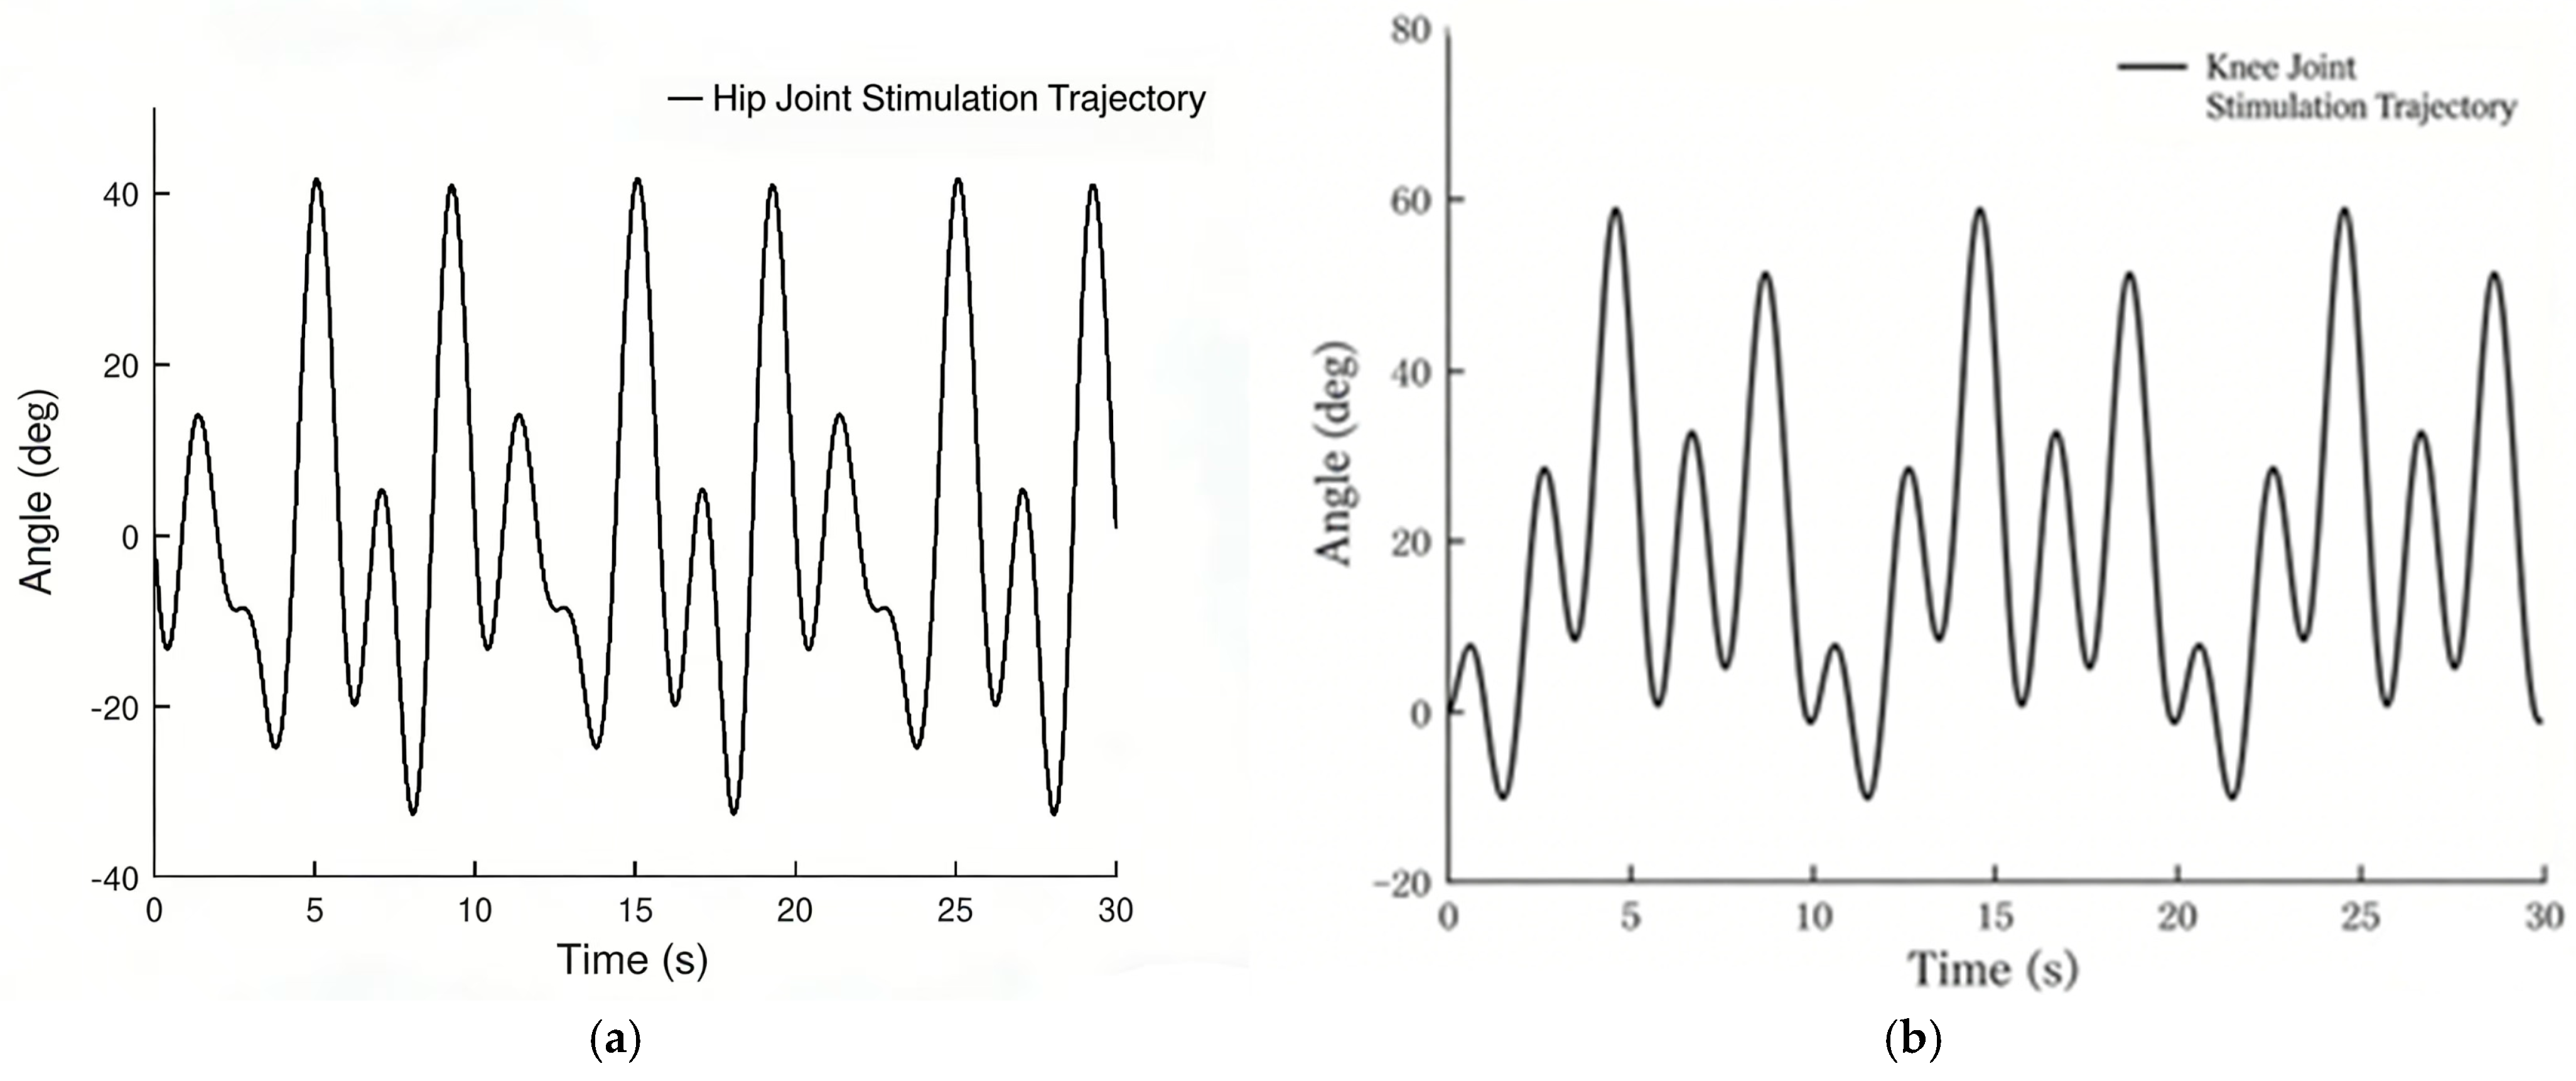
Table 2 into the Fourier series form shown in Equation (21), the excitation trajectories for the thigh and shank are generated, respectively. The resulting angle, angular velocity, and angular acceleration curves are illustrated in
Figure 5. Verification confirms that all kinematic quantities of the designed excitation trajectory satisfy the safety constraint ranges specified in
Table 1. This ensures the trajectory can fully excite the system’s dynamic characteristics while maintaining safe operation of the exoskeleton.
5.3. Simulation and Verification of the Improved Grey Wolf Optimizer
After obtaining the designed excitation trajectory, it is used as the desired input to drive a two-degree-of-freedom lower-limb exoskeleton robot model via a Proportional-Integral-Derivative (PID) controller. The resulting hip and knee joint angles, angular velocities, angular accelerations, and the torque output from the PID controller are collected. For the dynamic model parameter identification experiments, a comparative study is conducted using four algorithms: the Grey Wolf Optimizer (GWO), the Genetic Algorithm (GA), the Lens Imaging Learning-based Grey Wolf Optimizer (LIL_GWO) [
29], and the proposed Tent-GA-GWO. All compared algorithms employ identical parameter settings to ensure fairness. The rationale for parameter selection is detailed in
Section 5.1.
The LIL_GWO is an improved GWO based on the lens imaging learning principle. This algorithm has a solid theoretical foundation, and the relevant literature provides sufficient comparative experiments and sample data. GWO and GA are the original swarm intelligence algorithms upon which the Tent-GA-GWO is built. Using them as benchmarks allows for a clear demonstration of the performance improvements achieved by the enhanced algorithm. Therefore, these three algorithms are selected for comparison. Their specific parameters, presented as reference values in
Table 2, and the identification results are shown in
Table 3.
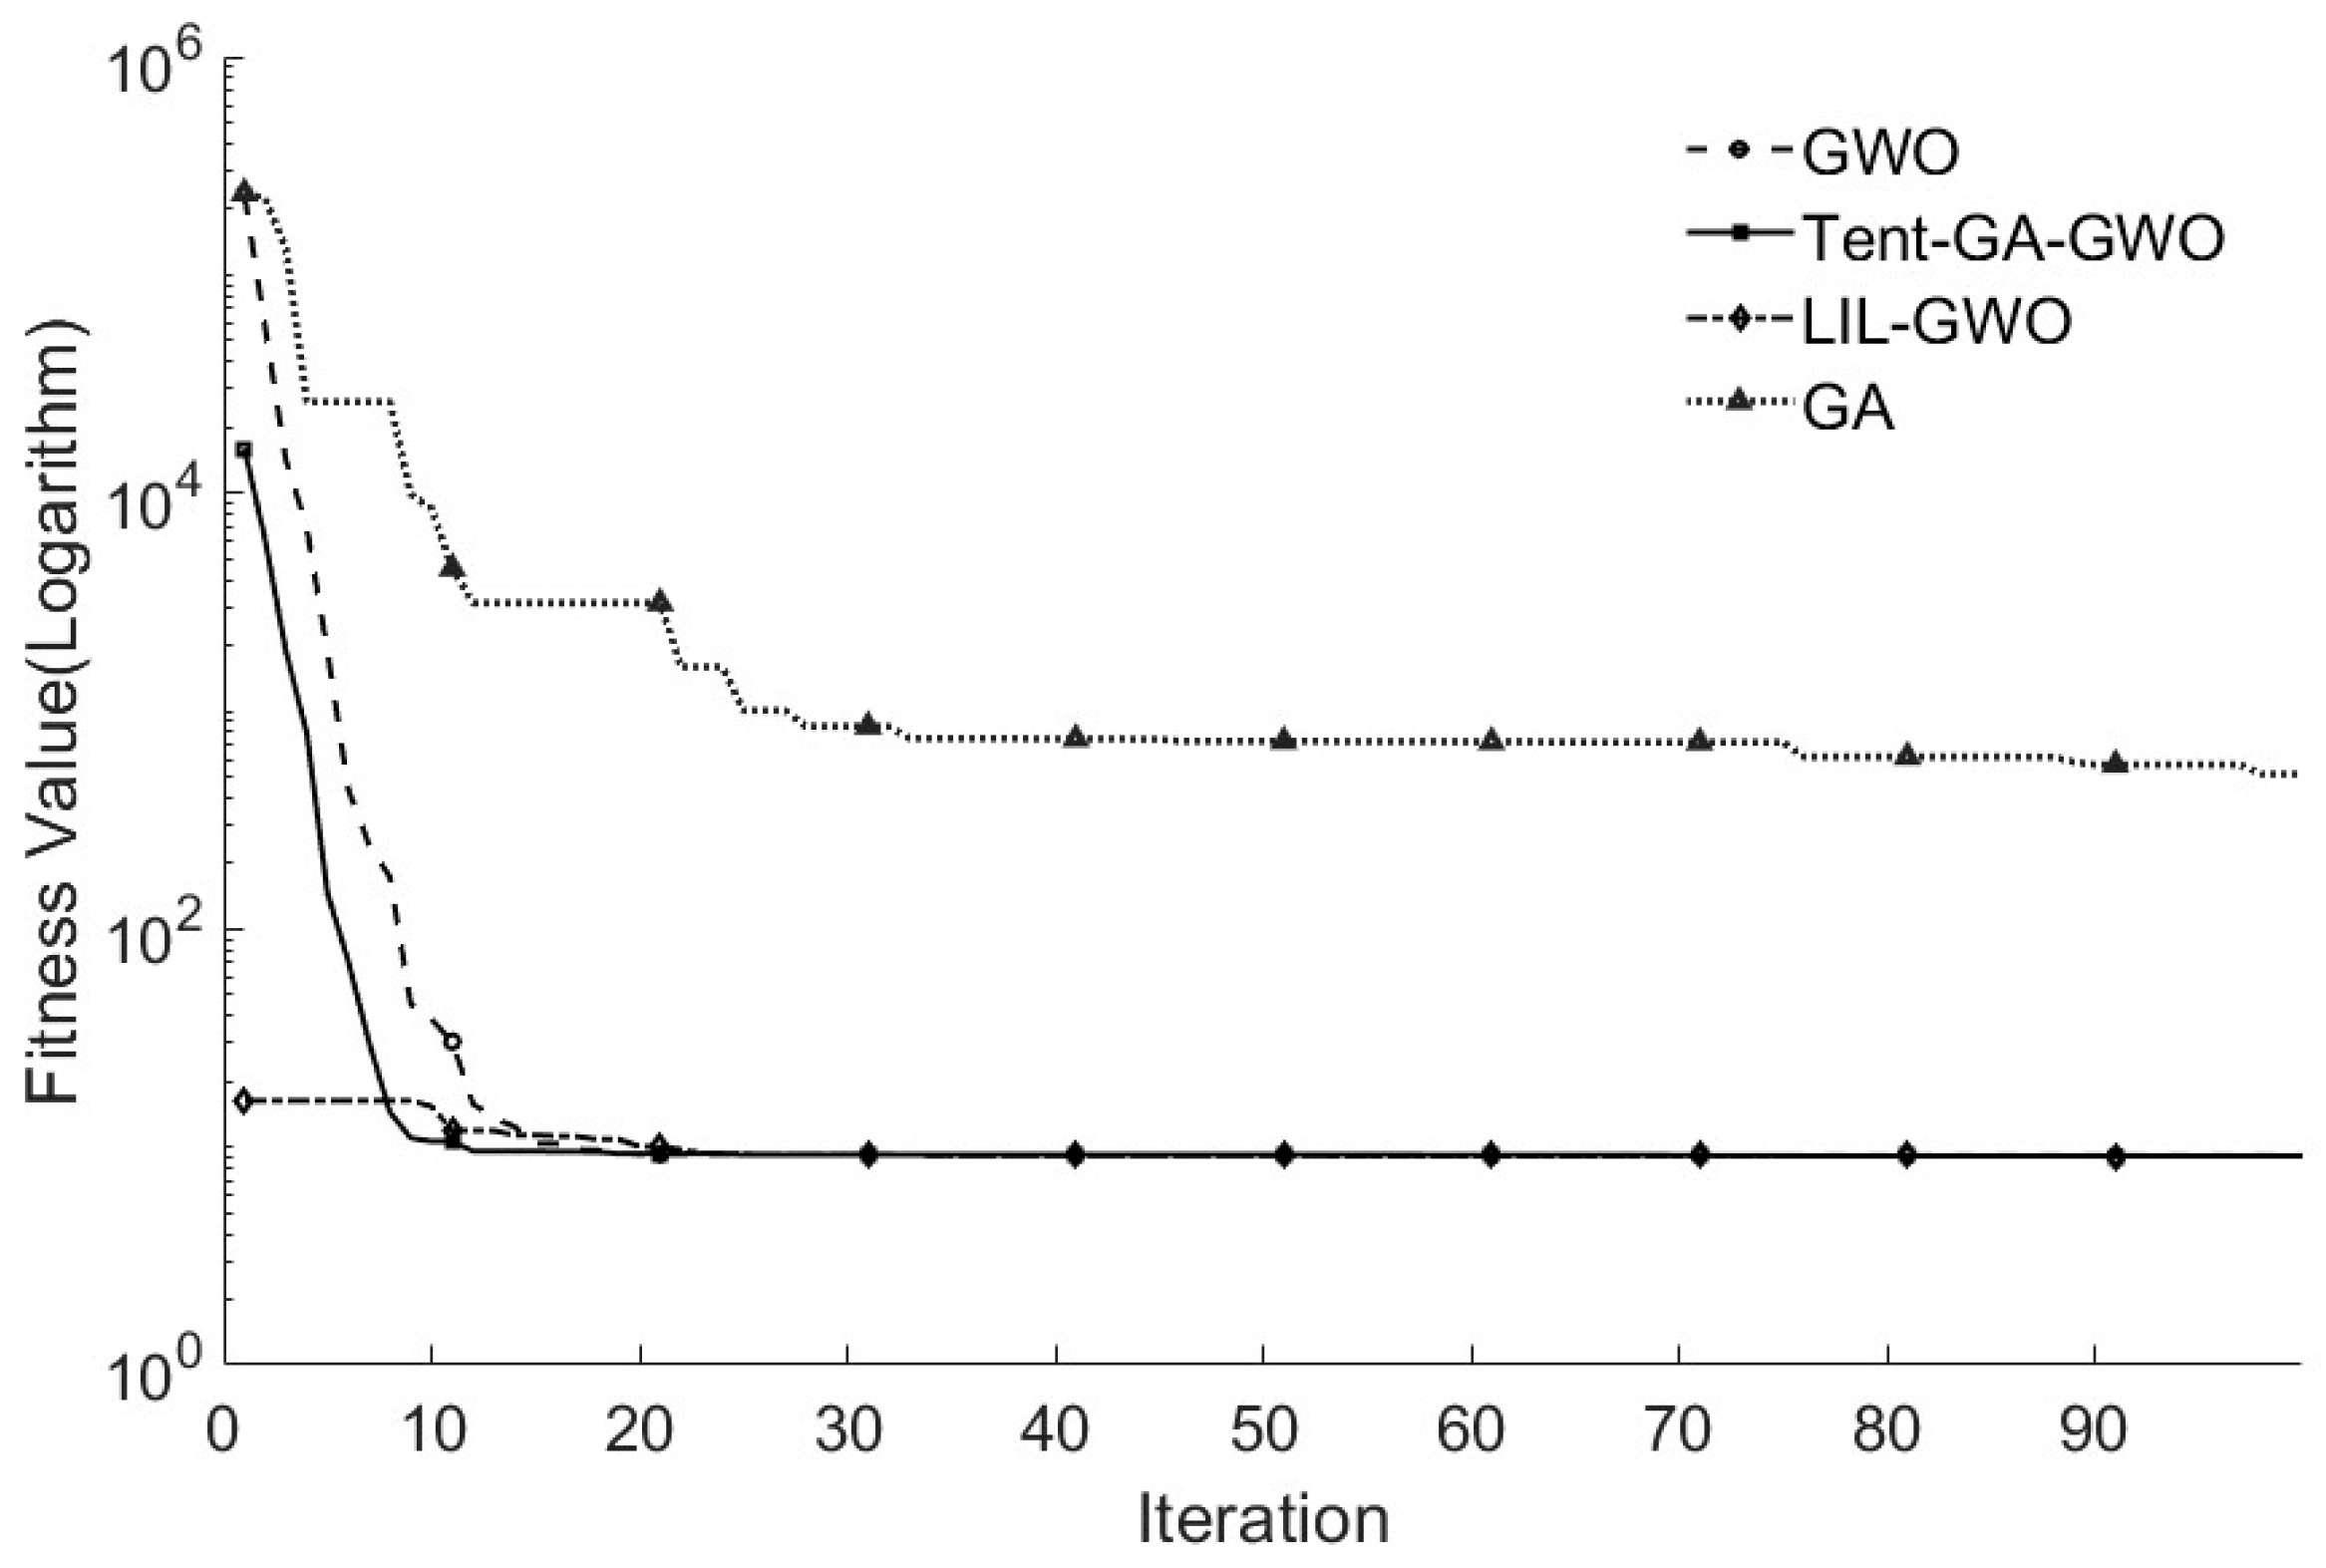
Through a comprehensive analysis of the parameter identification results (
Table 3) and the convergence curves (
Figure 6), the significant advantages of the improved Grey Wolf Optimizer (Tent-GA-GWO) can be clearly demonstrated:
First, it exhibits superior convergence speed. As shown in the convergence curves, Tent-GA-GWO reaches a stable optimum after approximately 12 iterations, representing an improvement in convergence efficiency of about 32.1% compared to the standard GWO, indicating a much faster optimization process. Second, it achieves higher fitness accuracy. The optimal fitness value of Tent-GA-GWO is reduced by 0.26% compared to the standard GWO. Since a lower fitness value corresponds to higher identification accuracy, this clearly highlights its precision advantage. Third, it provides more accurate parameter identification. Judging from the parameter identification results in
Table 2, the parameters identified by Tent-GA-GWO are closer to the optimal values than those from the standard GWO and are superior to the results obtained by both GA and LIL_GWO.
In summary, Tent-GA-GWO demonstrates outstanding performance in convergence speed, fitness accuracy, and parameter identification precision, fully validating the effectiveness and superiority of the proposed improvements.
6. Experiment on Dynamic Parameter Identification for the Exoskeleton
To further validate the engineering practicality of the algorithm, this section establishes an experimental platform using a two-degree-of-freedom lower-limb exoskeleton prototype. Trajectory tracking experiments were conducted based on the designed excitation trajectory. The measured data were utilized to drive the Tent-GA-GWO algorithm for parameter identification. Finally, the accuracy of the identification results and the feasibility of the method were verified by comparing the computed torque with the actual output torque.
6.1. Introduction to the Experimental Platform
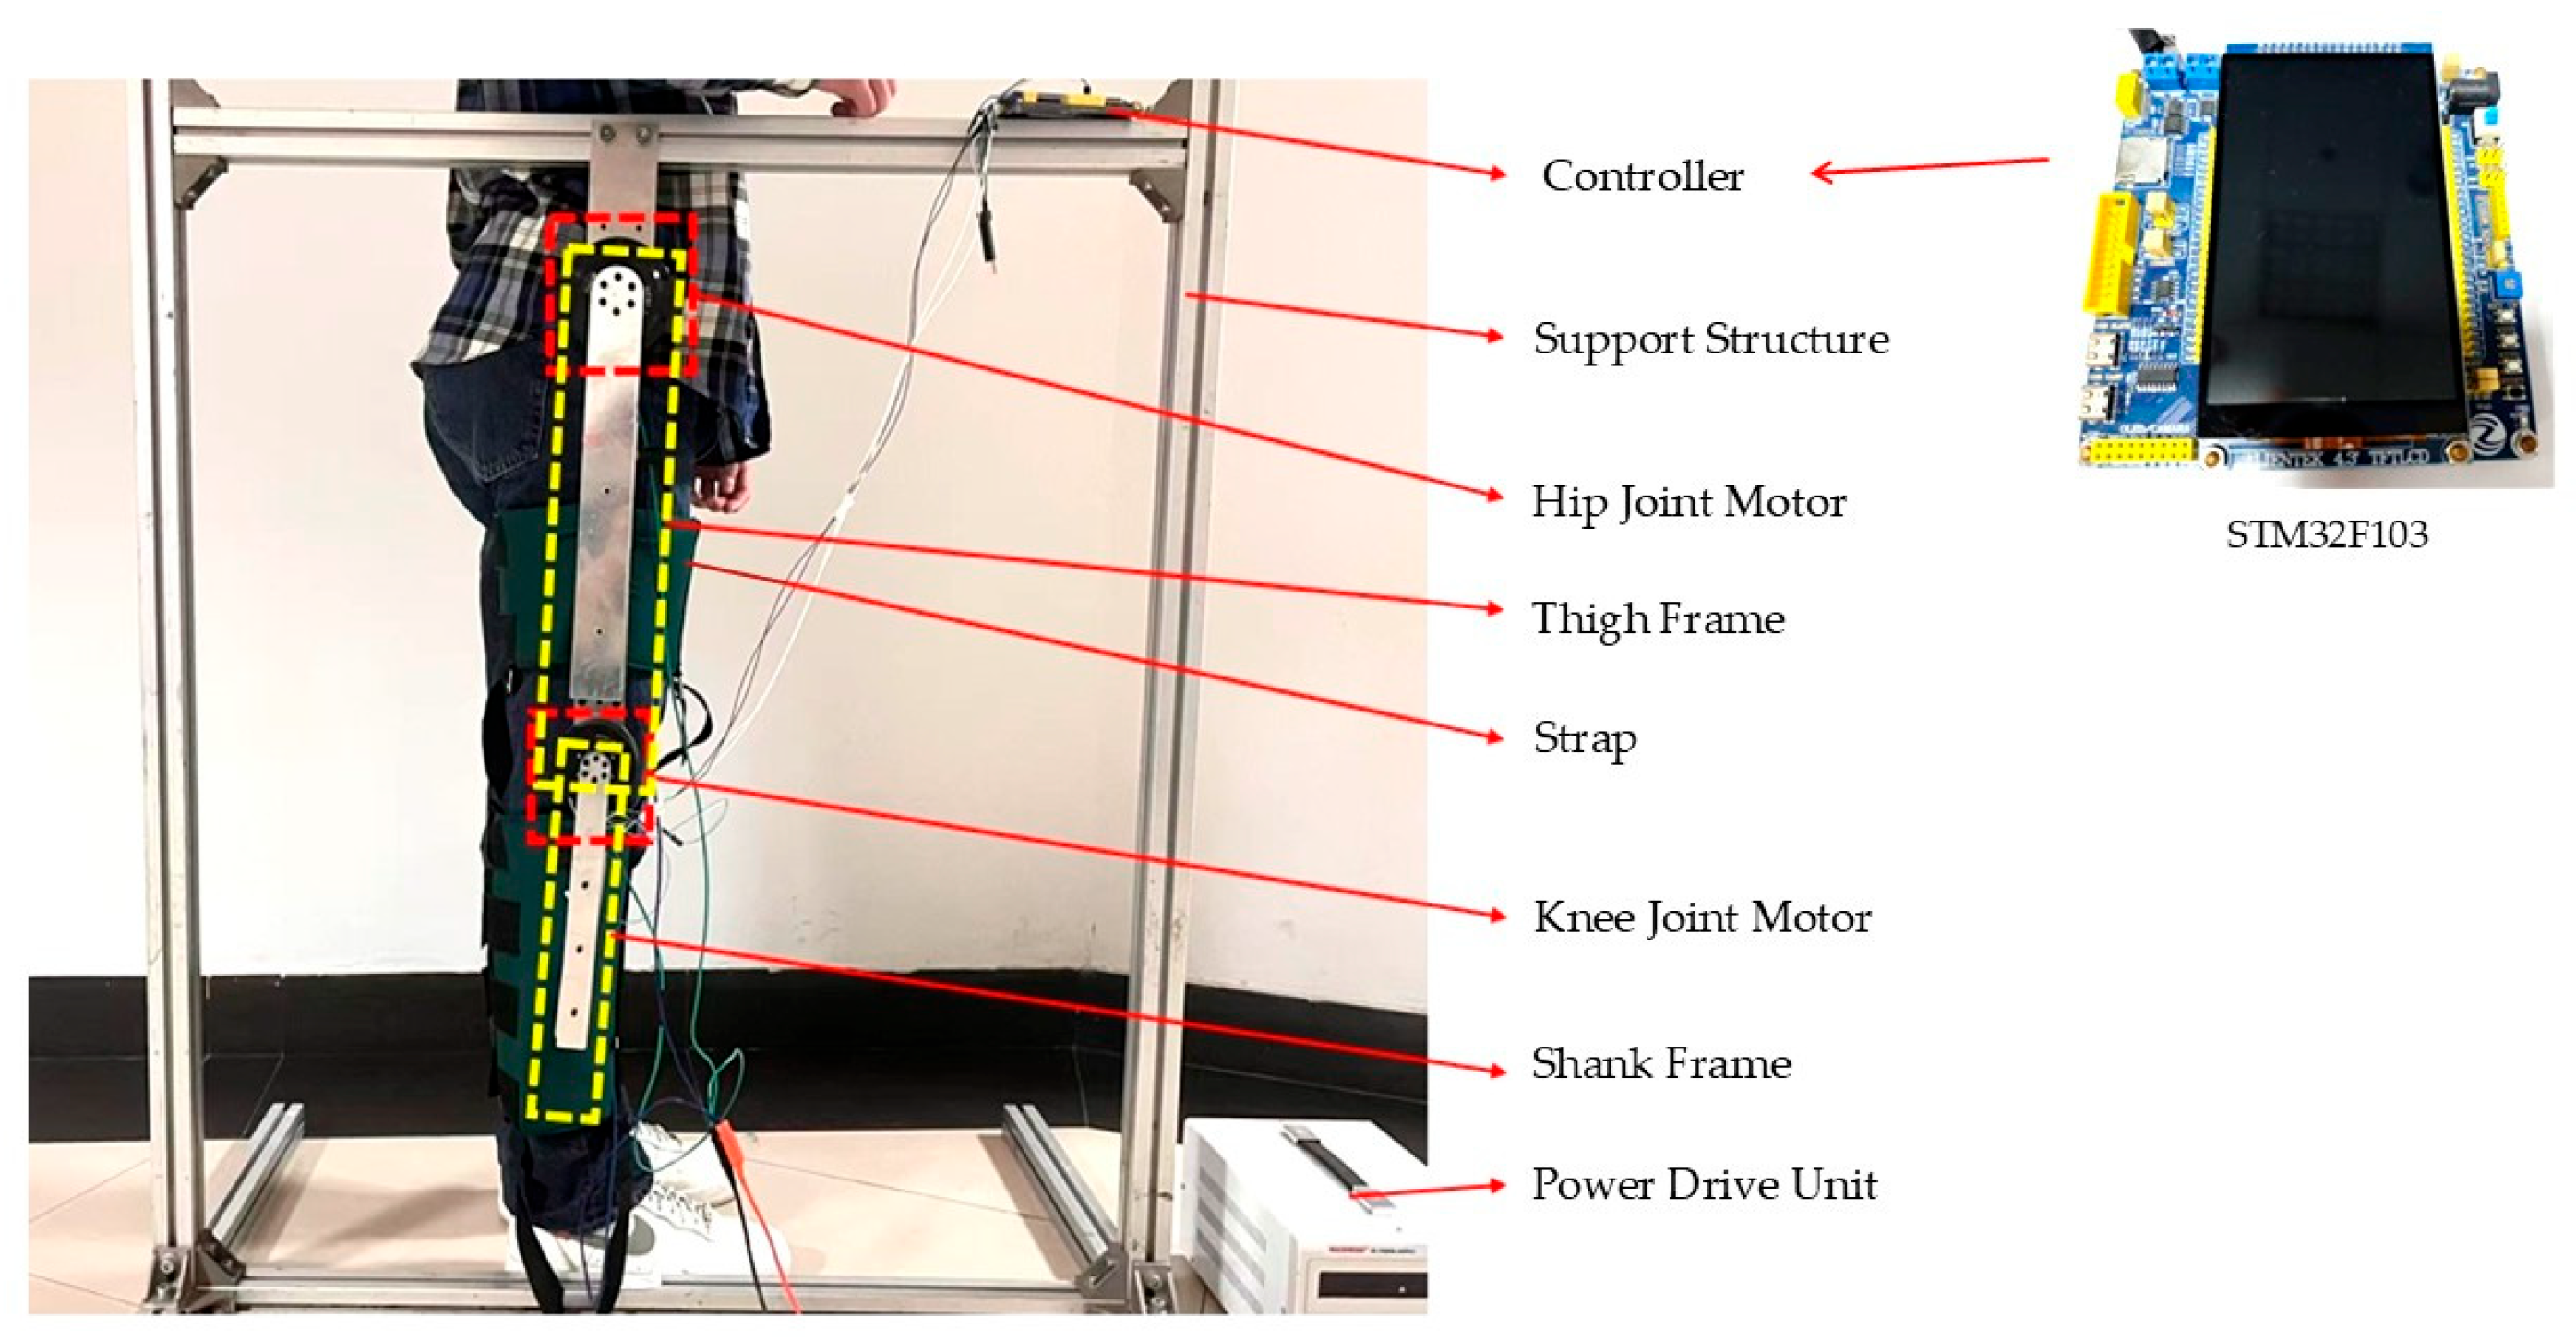
To validate the effectiveness of the improved Grey Wolf Optimizer in identifying dynamic model parameters for exoskeleton robots, a dedicated experimental platform is required to provide real measured data support. Accordingly, a single-leg two-degree-of-freedom lower-limb exoskeleton robot experimental platform was designed (its detailed mechanical structure is shown in
Figure 7). In the structural design of the platform, to ensure stability during prototype movement, the base support frame is constructed from aluminum profiles, and the hip joint is fixed to this frame. To meet the core requirement that the exoskeleton robot must match human body dimensions, aluminum alloy plates are used to connect the hip and knee joint motors. Furthermore, an innovative sliding rail adjustment mechanism is employed. By flexibly adjusting the distance between the two joint motors, synchronized movement between the joint motors and the human hip and knee joints is achieved, providing a real measurement basis that conforms to human motion characteristics for dynamic model parameter identification.
To optimize the lightweight design of the two-degree-of-freedom lower-limb exoskeleton robot experimental platform, this paper specifically selects the AK80-64 KV80 and AK10-9 KV60 integrated motors manufactured by CubeMars (Nanchang, China) for the hip and knee joint drives, respectively. The key advantage of this selection lies in the high integration of these two motor models, which combine high-performance brushless motors, planetary gear reducers, encoders, and servo drivers. This not only significantly reduces the overall weight of the platform (hip joint motor mass: 0.85 kg; knee joint motor mass: 0.96 kg) but also enables smooth operation under high torque. Their portable drive solutions support both servo and motion control modes, fulfilling the requirements for synchronous control of joint position, velocity, and acceleration. Moreover, the built-in adaptive PID algorithm eliminates the need for complex motor control tuning steps, directly ensuring precise drive control.
To further optimize system wiring and communication reliability, all motor cables communicate with the central STM32 (a microcontroller unit based on the ARM Cortex-M3 core, manufactured by STMicroelectronics, Geneva, Switzerland) controller via the Controller Area Network (CAN) bus. This design effectively reduces cable complexity and communication interface usage while ensuring stable and reliable data transmission, synergistically supporting the lightweight design objectives. To meet system communication requirements, the control center utilizes a Zhengtian Atomic Elite STM32F103 development board (manufactured by Zhengdian Yuanzi (Atomic) Technology Co., Ltd., Guangzhou, China; shown in
Figure 7). It is equipped with an STM32F103ZE main control chip operating at 72 MHz and features rich interfaces such as CAN communication and Universal Serial Bus (USB)-to-serial communication, fully satisfying the multi-channel communication needs between the motors and the host computer. Additionally, the development board integrates hardware modules such as buttons, indicator lights, and a 2.8-inch Liquid Crystal Display (LCD) screen, providing convenient support for real-time debugging and status monitoring during program development, thereby indirectly enhancing system development efficiency.
The software system of this experimental platform adopts a layered architecture design, primarily consisting of two parts: the STM32 embedded control board and the PC host computer. The STM32 control board, serving as the core lower-level controller, is designed to implement three main functions. First, the motion control module converts algorithm-generated control commands into standard Controller Area Network (CAN) communication protocol messages. These messages contain motor operating mode selection commands and joint angle setpoints, which are sent as real-time control signals to the drive motors at a fixed frequency of 100 Hz. Second, the data acquisition module parses the CAN messages fed back by the motors, decodes them, and extracts key state parameters such as joint angles, angular velocities, and current. The current signals are then converted into joint output torques based on the motor torque constant and gear reduction ratio. Finally, the communication transmission module packages the processed state data and transmits it to the PC host computer via the Universal Synchronous/Asynchronous Receiver/Transmitter (USART) serial protocol. The host computer software, utilizing a serial port debugging assistant, receives the data from the lower-level controller, displaying and saving key state parameters such as motor angle, angular velocity, and output torque.
6.2. Presentation of Experimental Results
To validate the effectiveness of the motion control system for the two-degree-of-freedom lower limb exoskeleton robot test platform, the excitation trajectory designed in
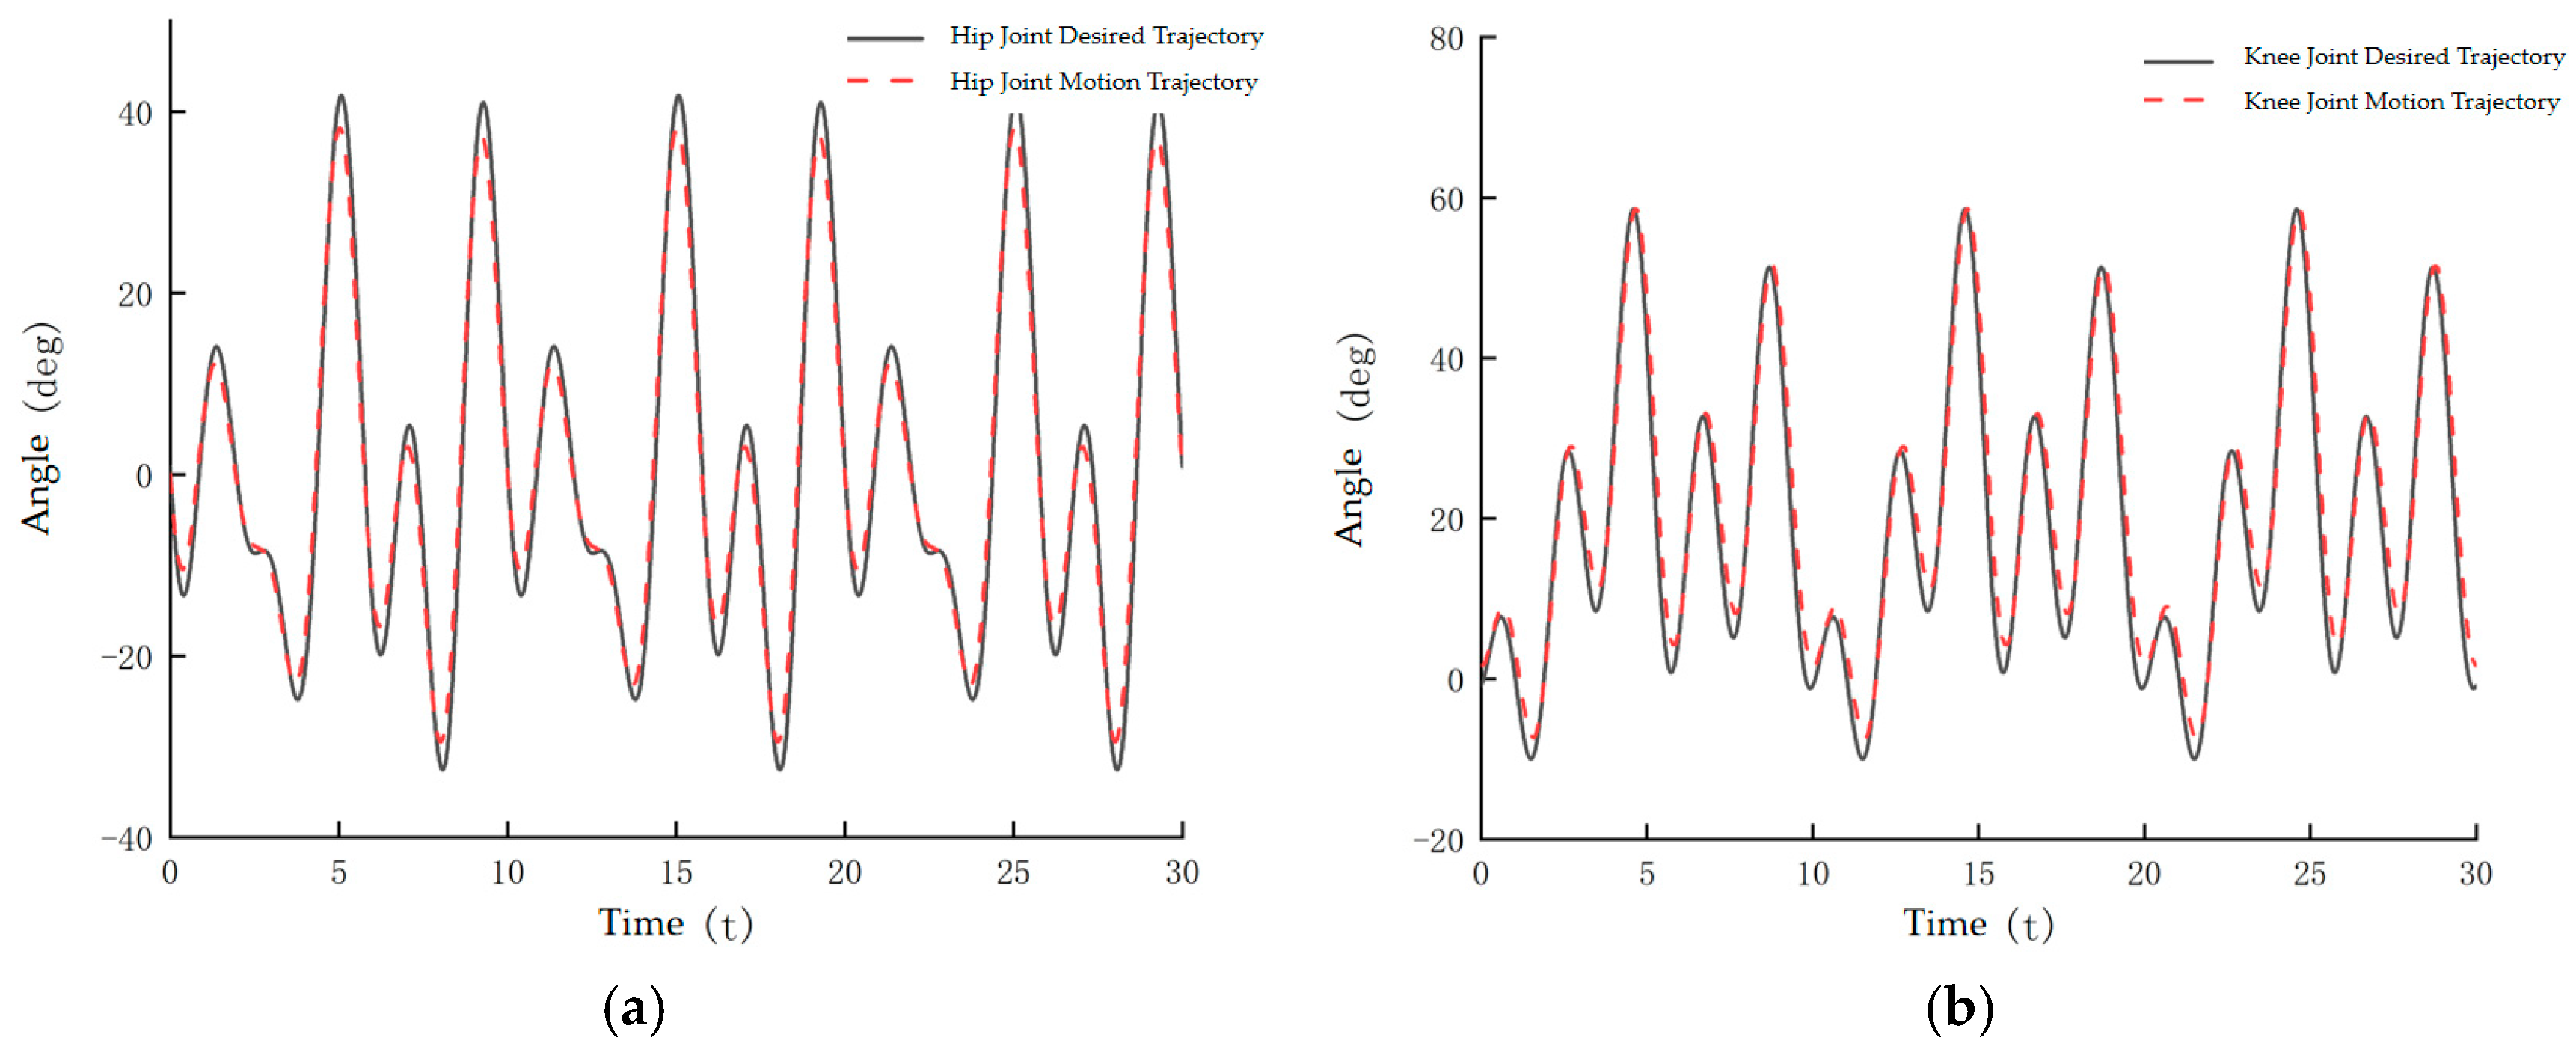
Section 5.2 was used as the desired motion trajectory for the robot. A PID controller was employed to drive the prototype in performing the trajectory tracking experiment. The experimental results are shown in
Figure 8. It can be clearly observed from the figure that the joint motion trajectory of the prototype demonstrates good consistency with the desired excitation trajectory, achieving accurate following of the desired trajectory. This result directly indicates that the motion control system of the test platform operates stably and reliably—it can adjust joint positions and robot posture in real-time according to commands, efficiently responding to trajectory tracking demands. Consequently, it proves the success of this excitation trajectory tracking experiment, laying a solid foundation for the subsequent smooth execution of the dynamic model parameter identification experiments.
To conduct the parameter identification experiment for the improved Grey Wolf Optimizer, the hip and knee joint angle, angular velocity, and angular acceleration data, along with the motor output torque data acquired from the aforementioned trajectory tracking experiment, were mapped to serve as the state variables and the actual output torque input in the algorithm, respectively. This data mapping approach aligns with the fundamental requirement for dynamic model parameter identification, providing the algorithm with authentic and valid input samples and thereby ensuring the rationality and reliability of the identification process. The final identification results based on the aforementioned data inputs are presented in
Table 4.
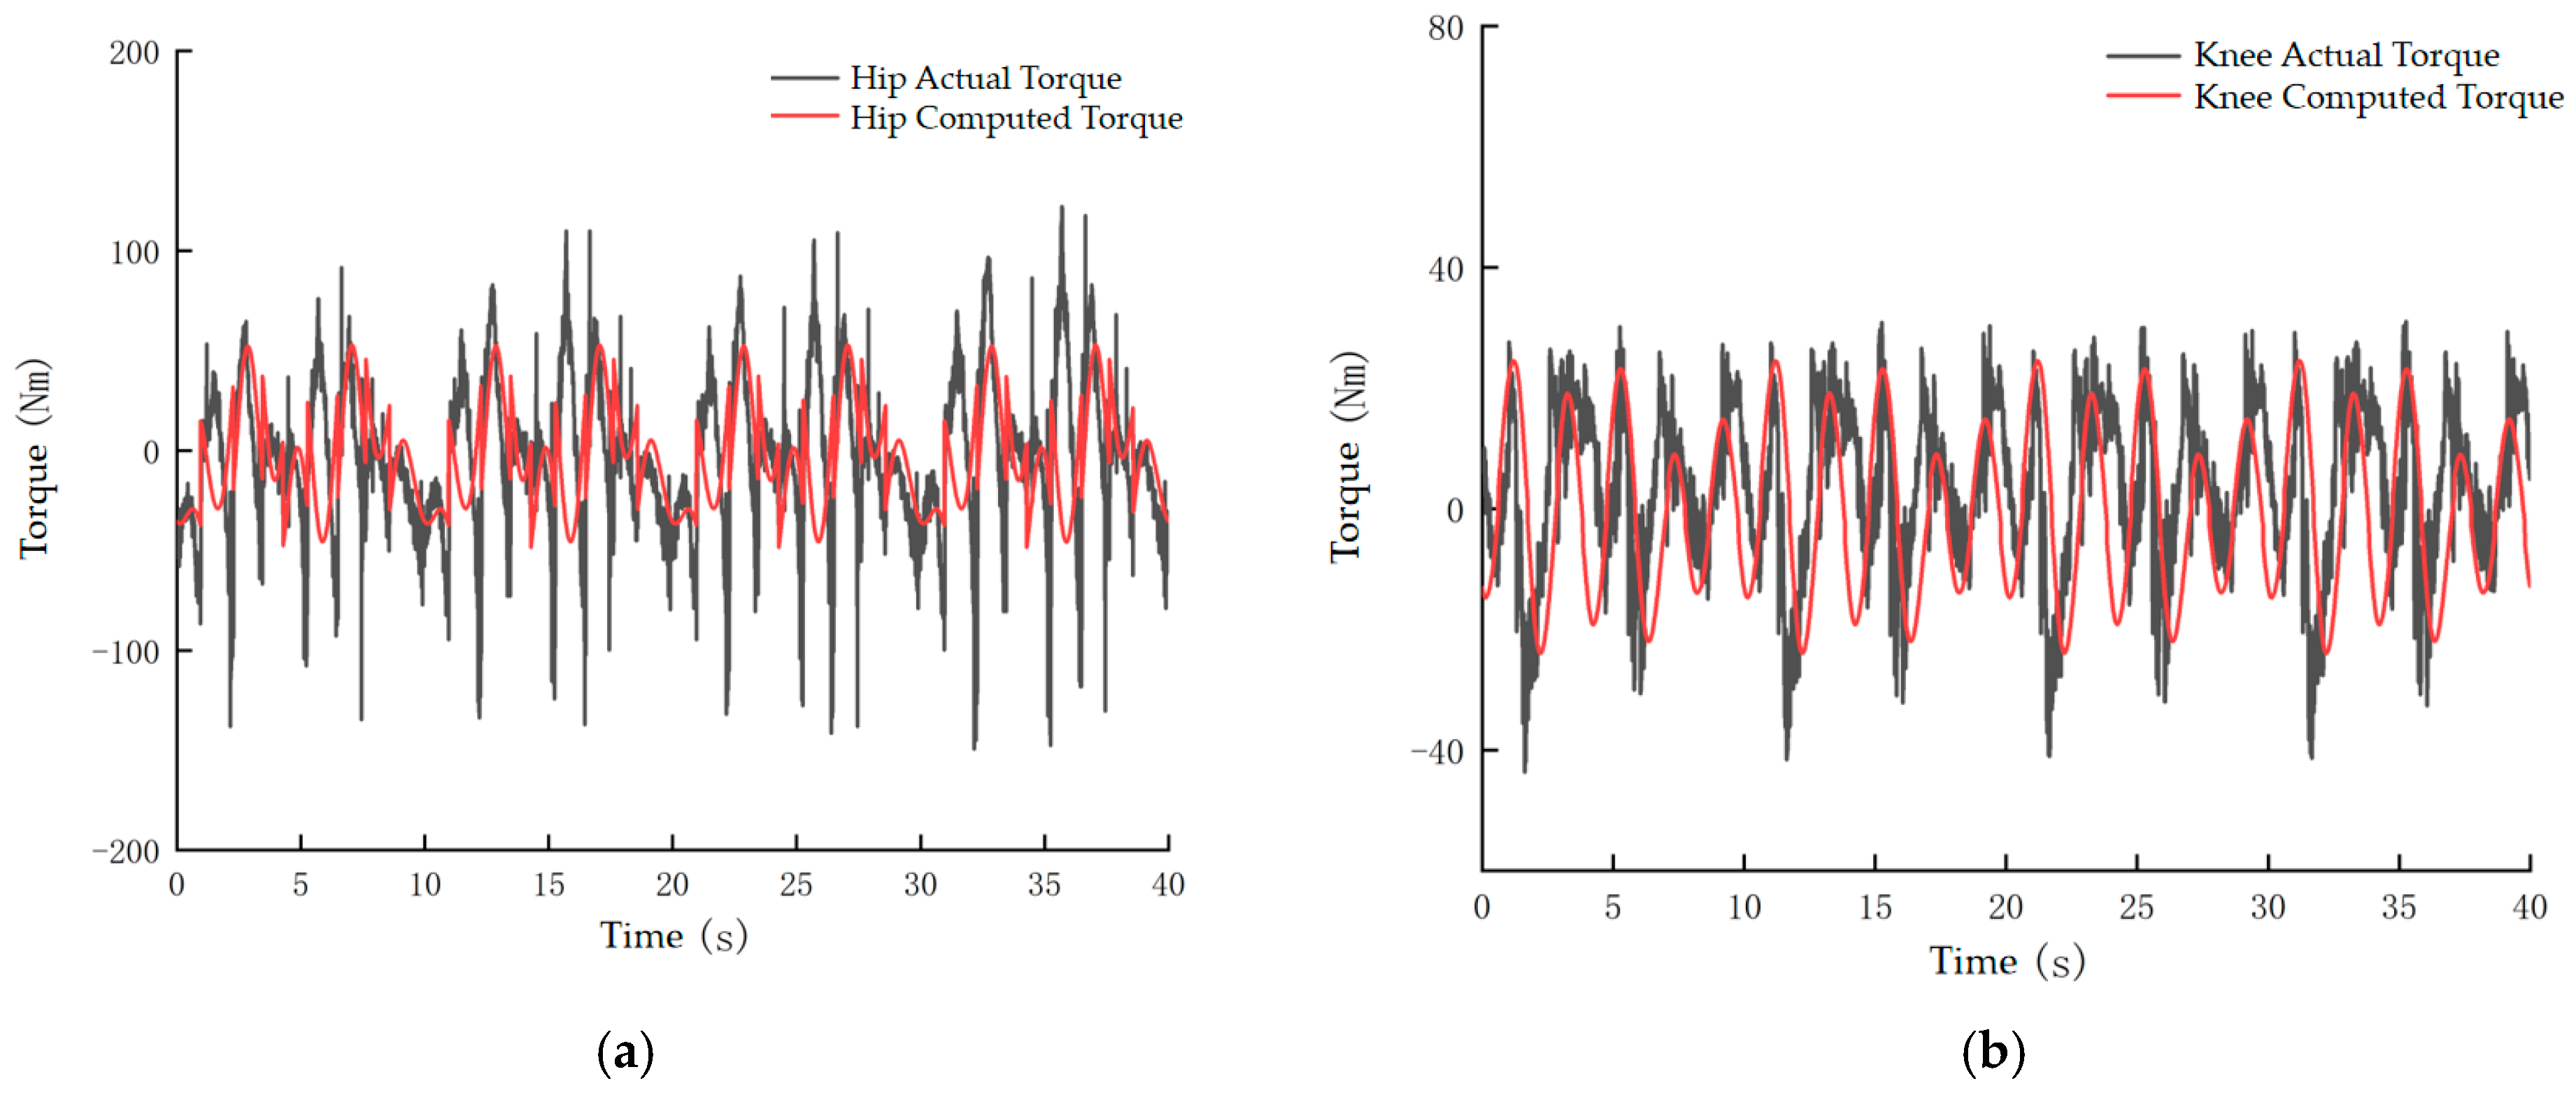
To verify the accuracy of the identification results, the identified dynamic parameter vector set
of the exoskeleton robot and the regression matrix
(composed of the angle, angular velocity, and angular acceleration of the hip and knee joints) are substituted into Formula (20). Through calculation, the calculated torques
of the hip and knee joints can be obtained. The calculated torques
are compared with the actual output torques
of the exoskeleton robot test platform, as shown in
Figure 9.
For the hip joint torque curve in
Figure 9a, the mean relative error between the calculated torque (derived from the identified parameters) and the actual output torque (fed back by the sensor) is approximately 8.5%, and the relative error of over 90% of the data points is controlled within 10%. For the knee joint torque curve in
Figure 9b, the mean relative error between the two is only about 6.2%, with more than 95% of the data points having a relative error not exceeding 9%. The two curves are highly consistent in trend and have good numerical consistency, which can meet the accuracy requirements in practical engineering. This verifies the effectiveness of the identification method, as well as the validity and feasibility of the identified parameters. Although the experimental parameter values identified in
Table 4 differ from the simulation reference values in
Table 3, this discrepancy primarily stems from the fundamental distinction between a real physical system and an idealized simulation model. As a complex real-world system, the experimental platform’s dynamic characteristics are influenced by multiple factors such as mechanical transmission backlash, link flexibility, cable damping, and nonlinear friction that were not precisely modeled. These unmodeled dynamics are absorbed into the equivalent parameters of the linearized model, leading to shifts in the parameter values. Nevertheless, the identified parameters maintain clear physical plausibility (e.g., parameters representing mass and inertia are positive and of an order of magnitude consistent with the mechanical structure). Their core value lies in their ability to predict the system’s output behavior with high accuracy. The strong agreement between the computed torque and the actual torque demonstrates that the identified parameter set effectively captures the equivalent dynamic characteristics of the real system, validating the effectiveness and feasibility of the Tent-GA-GWO algorithm in obtaining “engineering-practical” model parameters.
7. Conclusions
Aiming at the problem of uncertain dynamic parameters of exoskeletons caused by human lower limb differences, assembly errors, and wear, this paper proposes a dynamic parameter identification method for 2-degree-of-freedom (2-DOF) lower limb exoskeletons based on an improved Grey Wolf Optimizer (Tent-GA-GWO), to achieve accurate modeling and efficient control of the robot.
First, the research constructs a nonlinear dynamic model incorporating joint friction and link inertia via the Lagrange method. The Coulomb friction and viscous friction models are introduced to improve the authenticity of the model, which is further linearized to establish a direct mapping relationship between torque and state variables. To address the defects of the standard Grey Wolf Optimizer (GWO), such as uneven initialization, slow convergence speed, and easy trapping in local optima, the Tent chaotic mapping is adopted to optimize population initialization, nonlinear control parameters are designed to balance search behaviors, and the selection–crossover–mutation operators of the genetic algorithm (GA) are integrated to enhance population diversity, thus forming the improved Tent-GA-GWO algorithm. Meanwhile, an excitation trajectory based on Fourier series is designed, which takes into account both the physiological constraints of human motion and the demand for stimulating the system’s dynamic characteristics, providing effective input samples for parameter identification.
Simulation experiments show that the convergence speed of the Tent-GA-GWO algorithm is increased by 32.1% compared with the standard GWO, achieving a stable optimal state after about 12 iterations, with the fitness value reduced by 0.26%. The identified parameters are closer to the reference values, and the comprehensive performance is significantly superior to that of the GA and LIL_GWO algorithms. Verification on the physical experiment platform indicates that the calculated torque based on the parameters identified by Tent-GA-GWO is consistent with the actual output torque of the exoskeleton, and the test platform can accurately track the excitation trajectory, which proves that the algorithm has good engineering practicability.
This method effectively solves the core problems of low accuracy and poor efficiency in exoskeleton dynamic parameter identification, providing a high-precision and efficient parameter identification scheme for the dynamic modeling of lower limb exoskeleton robots. It enriches the application achievements of swarm intelligence algorithms in the field of robot parameter identification, and lays a theoretical and experimental foundation for the personalized control optimization of rehabilitation robots.
This study lays the foundation for parameter identification in lower-limb exoskeletons, and future work can be deepened across multiple dimensions. First, the algorithm’s robustness and generalization capability could be systematically evaluated under more complex disturbance conditions (such as sudden load changes and abnormal gait patterns) and extensively compared with advanced hybrid optimization algorithms to clarify its performance boundaries. To further enhance the statistical rigor of the conclusions, future research will increase the number of independent experiments and employ statistical methods such as paired t-tests to analyze the significance of improvements in convergence speed and fitness, thereby more systematically and robustly validating the performance advantages of the Tent-GA-GWO algorithm. Furthermore, the obtained high-precision model could be integrated with Virtual Reality (VR) environments or depth camera-based visual feedback to construct an integrated “perception–identification–control” human–machine interaction system, providing core support for achieving personalized and adaptive assistive control.