Article

Extended State Observer-Based Design of a Bilateral Dual-Kernel Fuzzy Control Algorithm

by
Chuqiang Liu
1,
Lujun Chen
1,2,
Zhulin Wang
3 and
Qunpo Liu
3,*
1
Huadian Coal Industry Group Digital Intelligence Technology Co., Ltd., Beijing 100035, China
2
School of Mechanical and Electrical Engineering, China University of Mining and Technology, Xuzhou 221116, China
3
School of Electrical Engineering and Automation, Henan Polytechnic University, Jiaozuo 454003, China
*
Author to whom correspondence should be addressed.
Mathematics 2026, 14(10), 1765; https://doi.org/10.3390/math14101765
Submission received: 24 April 2026 / Revised: 13 May 2026 / Accepted: 15 May 2026 / Published: 21 May 2026

Abstract

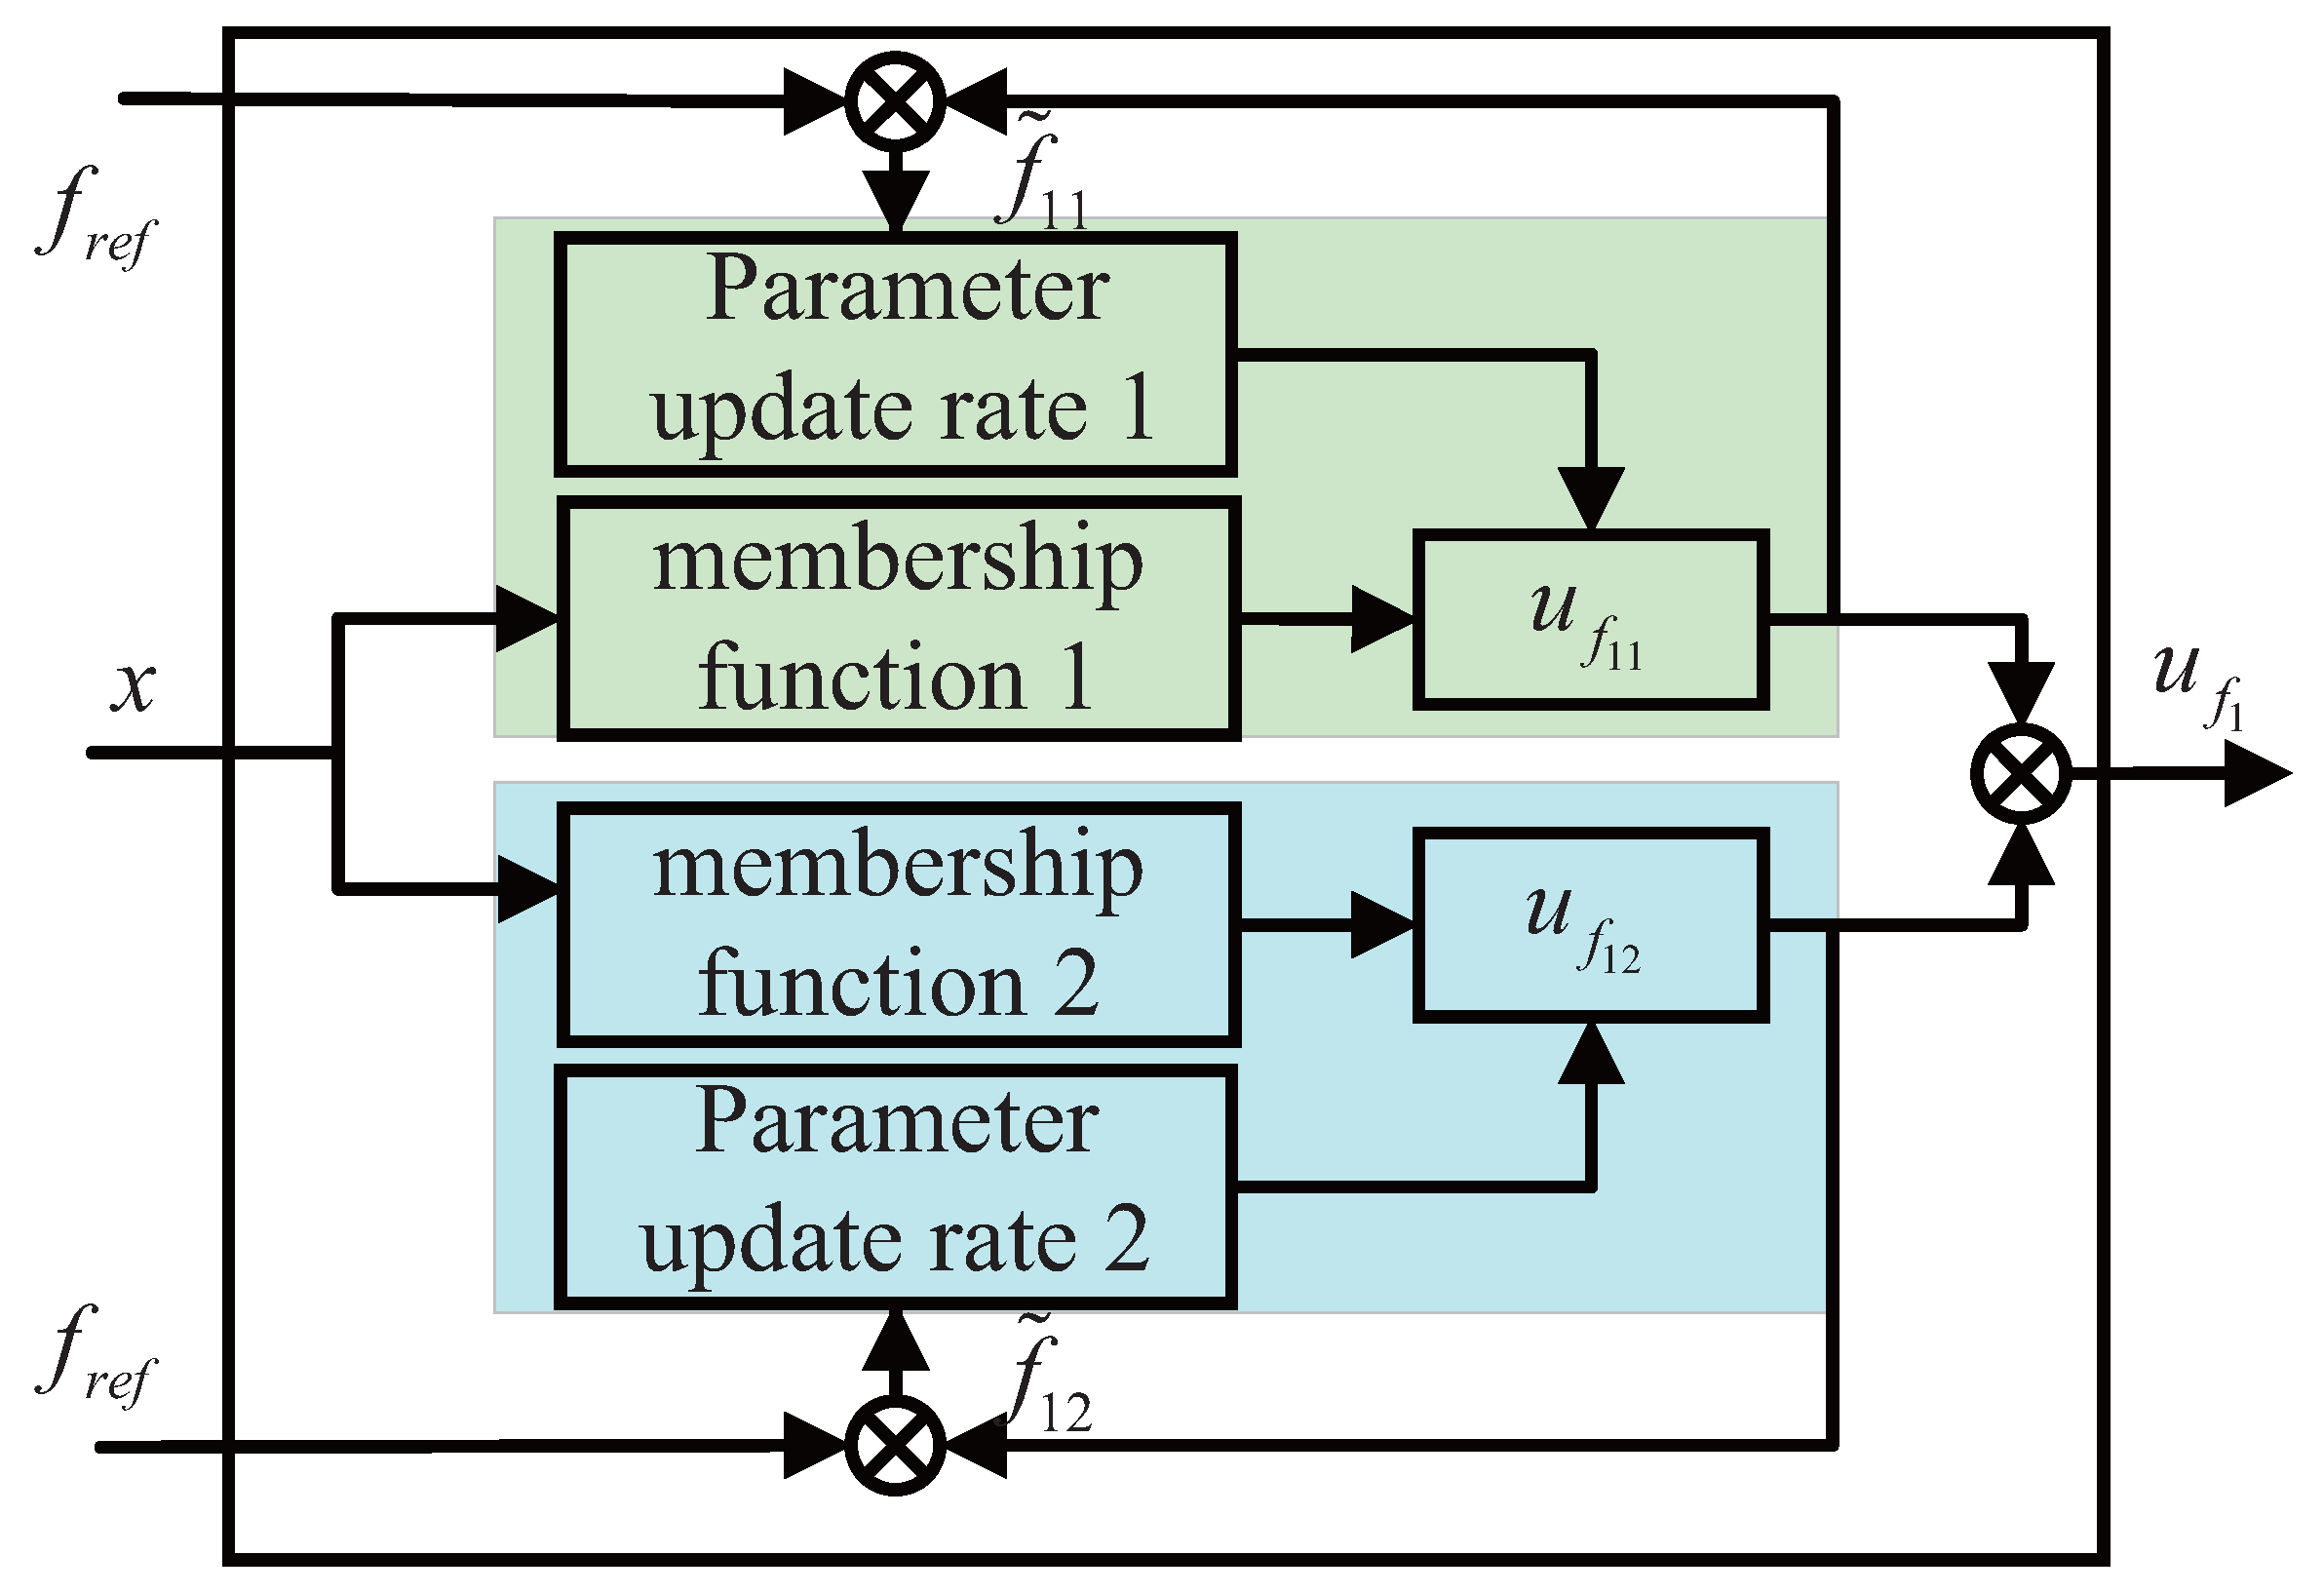
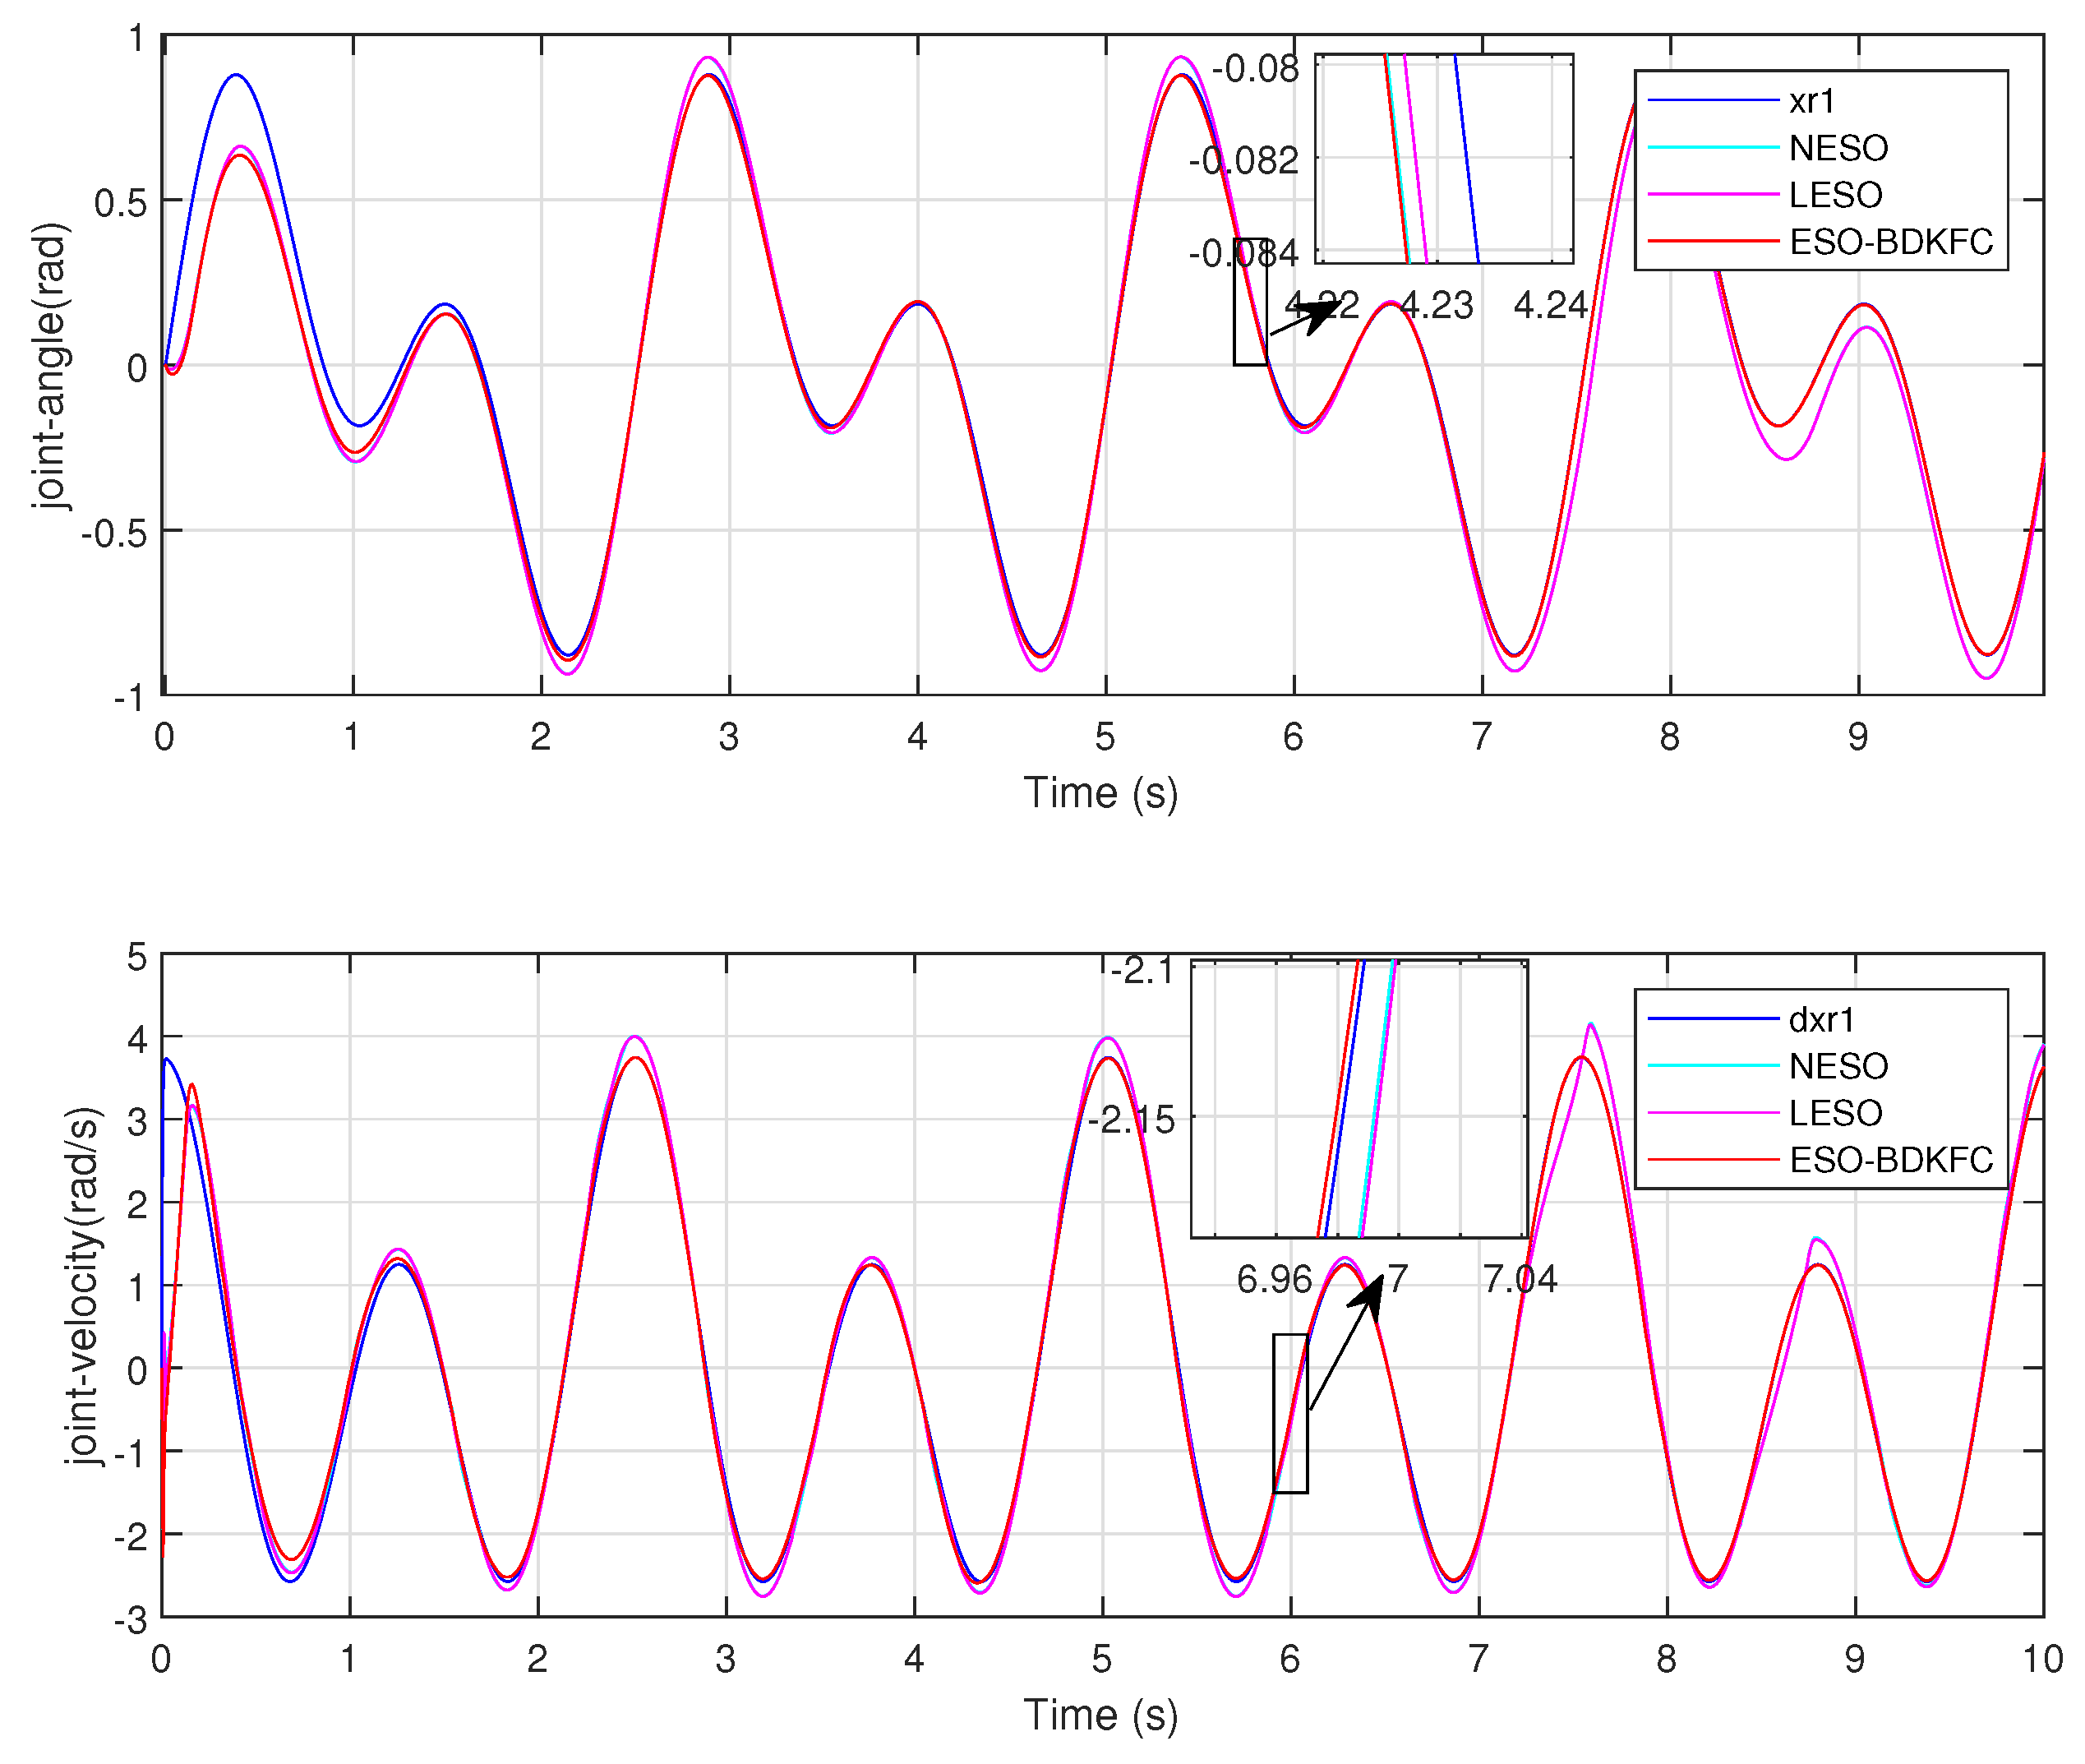
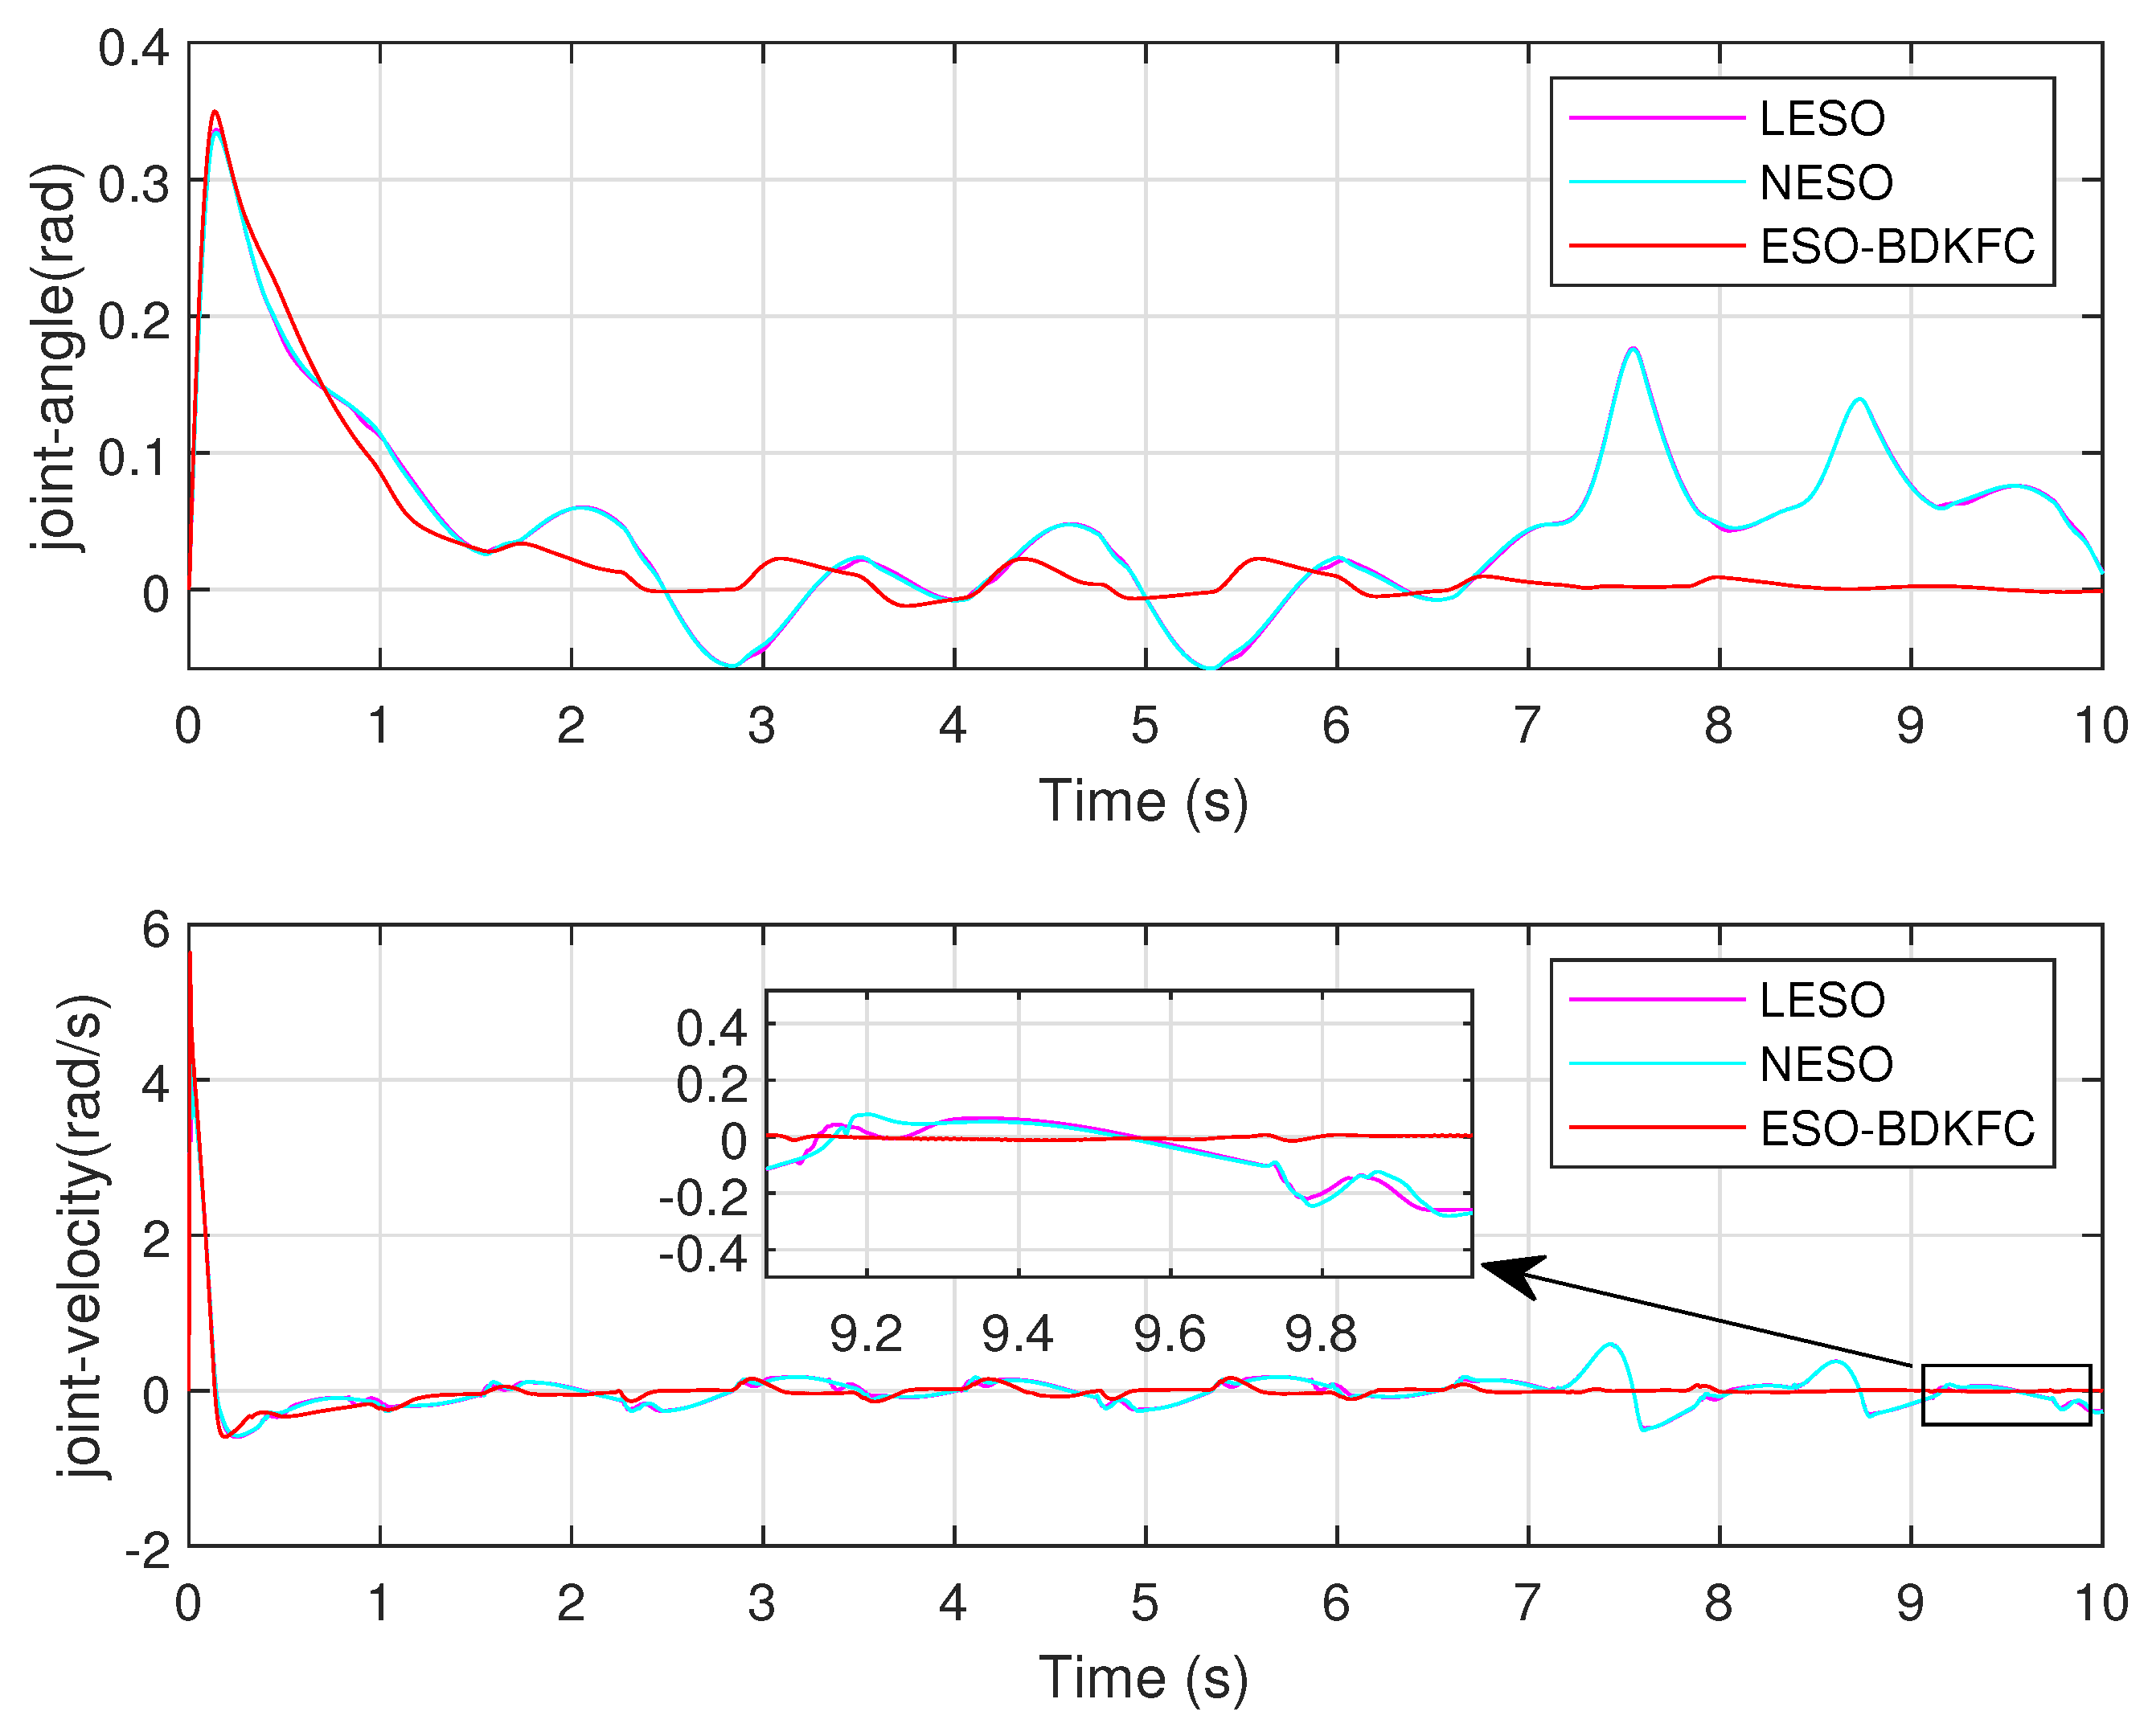
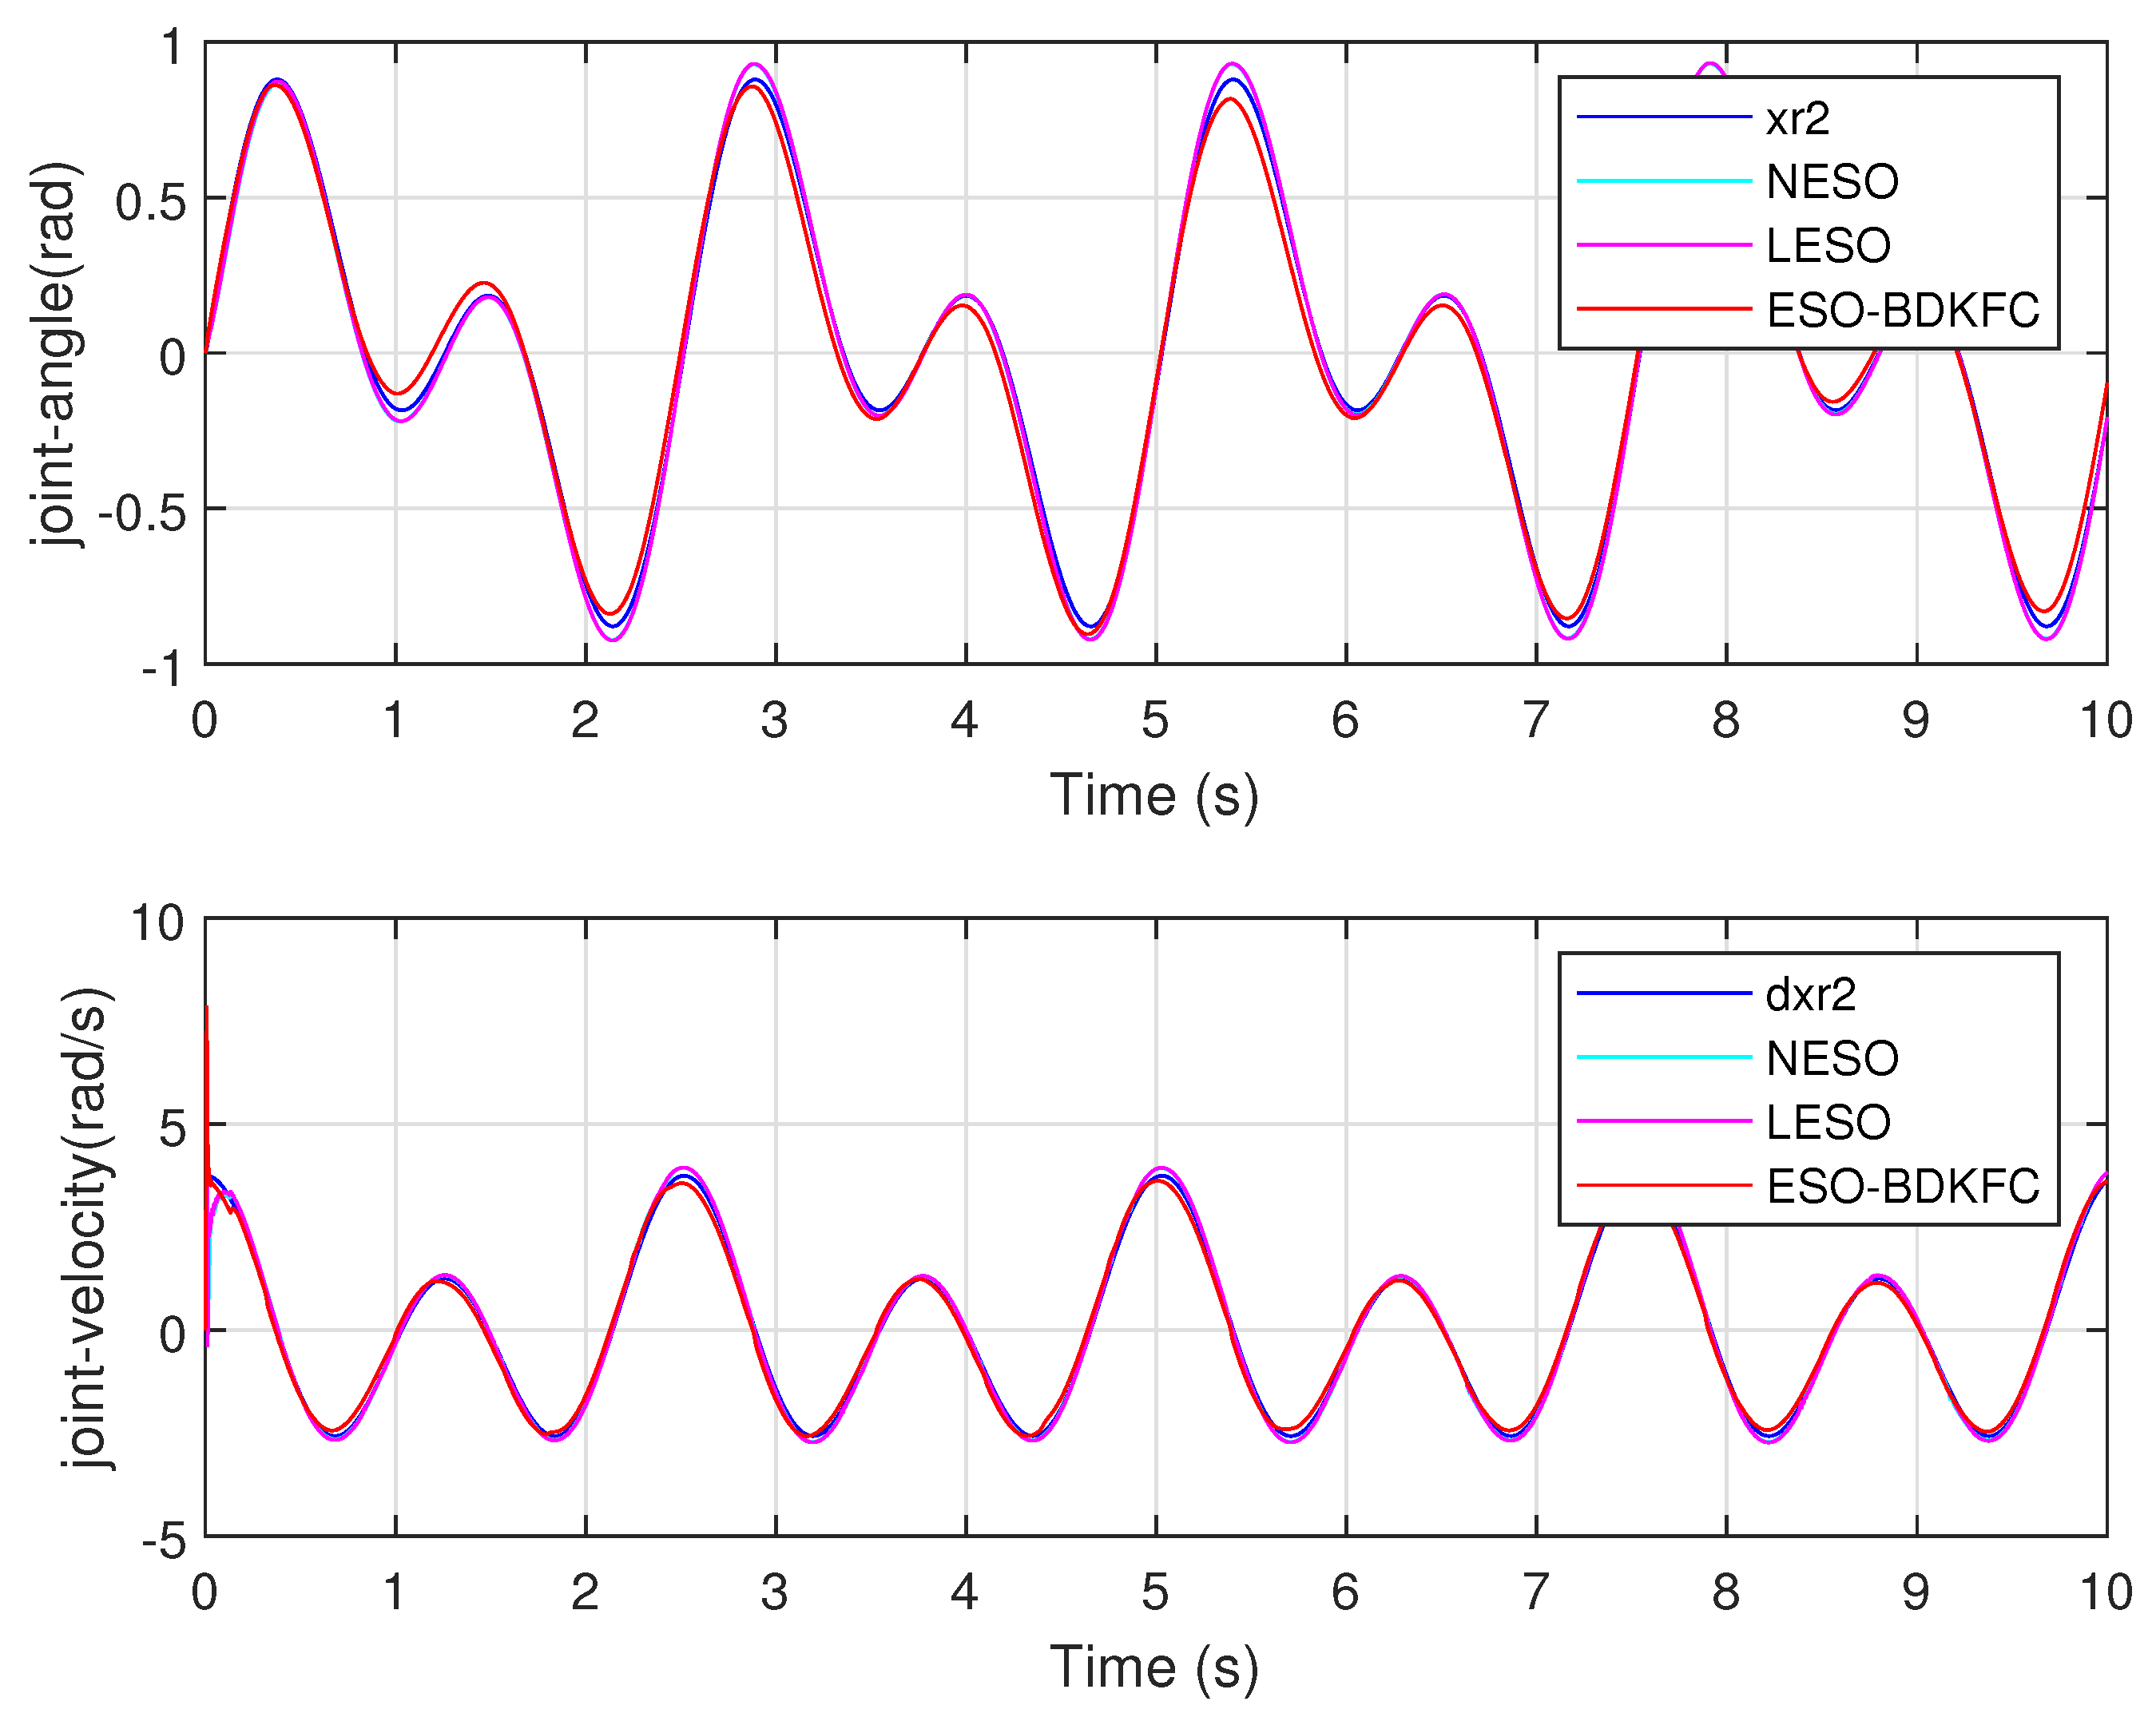
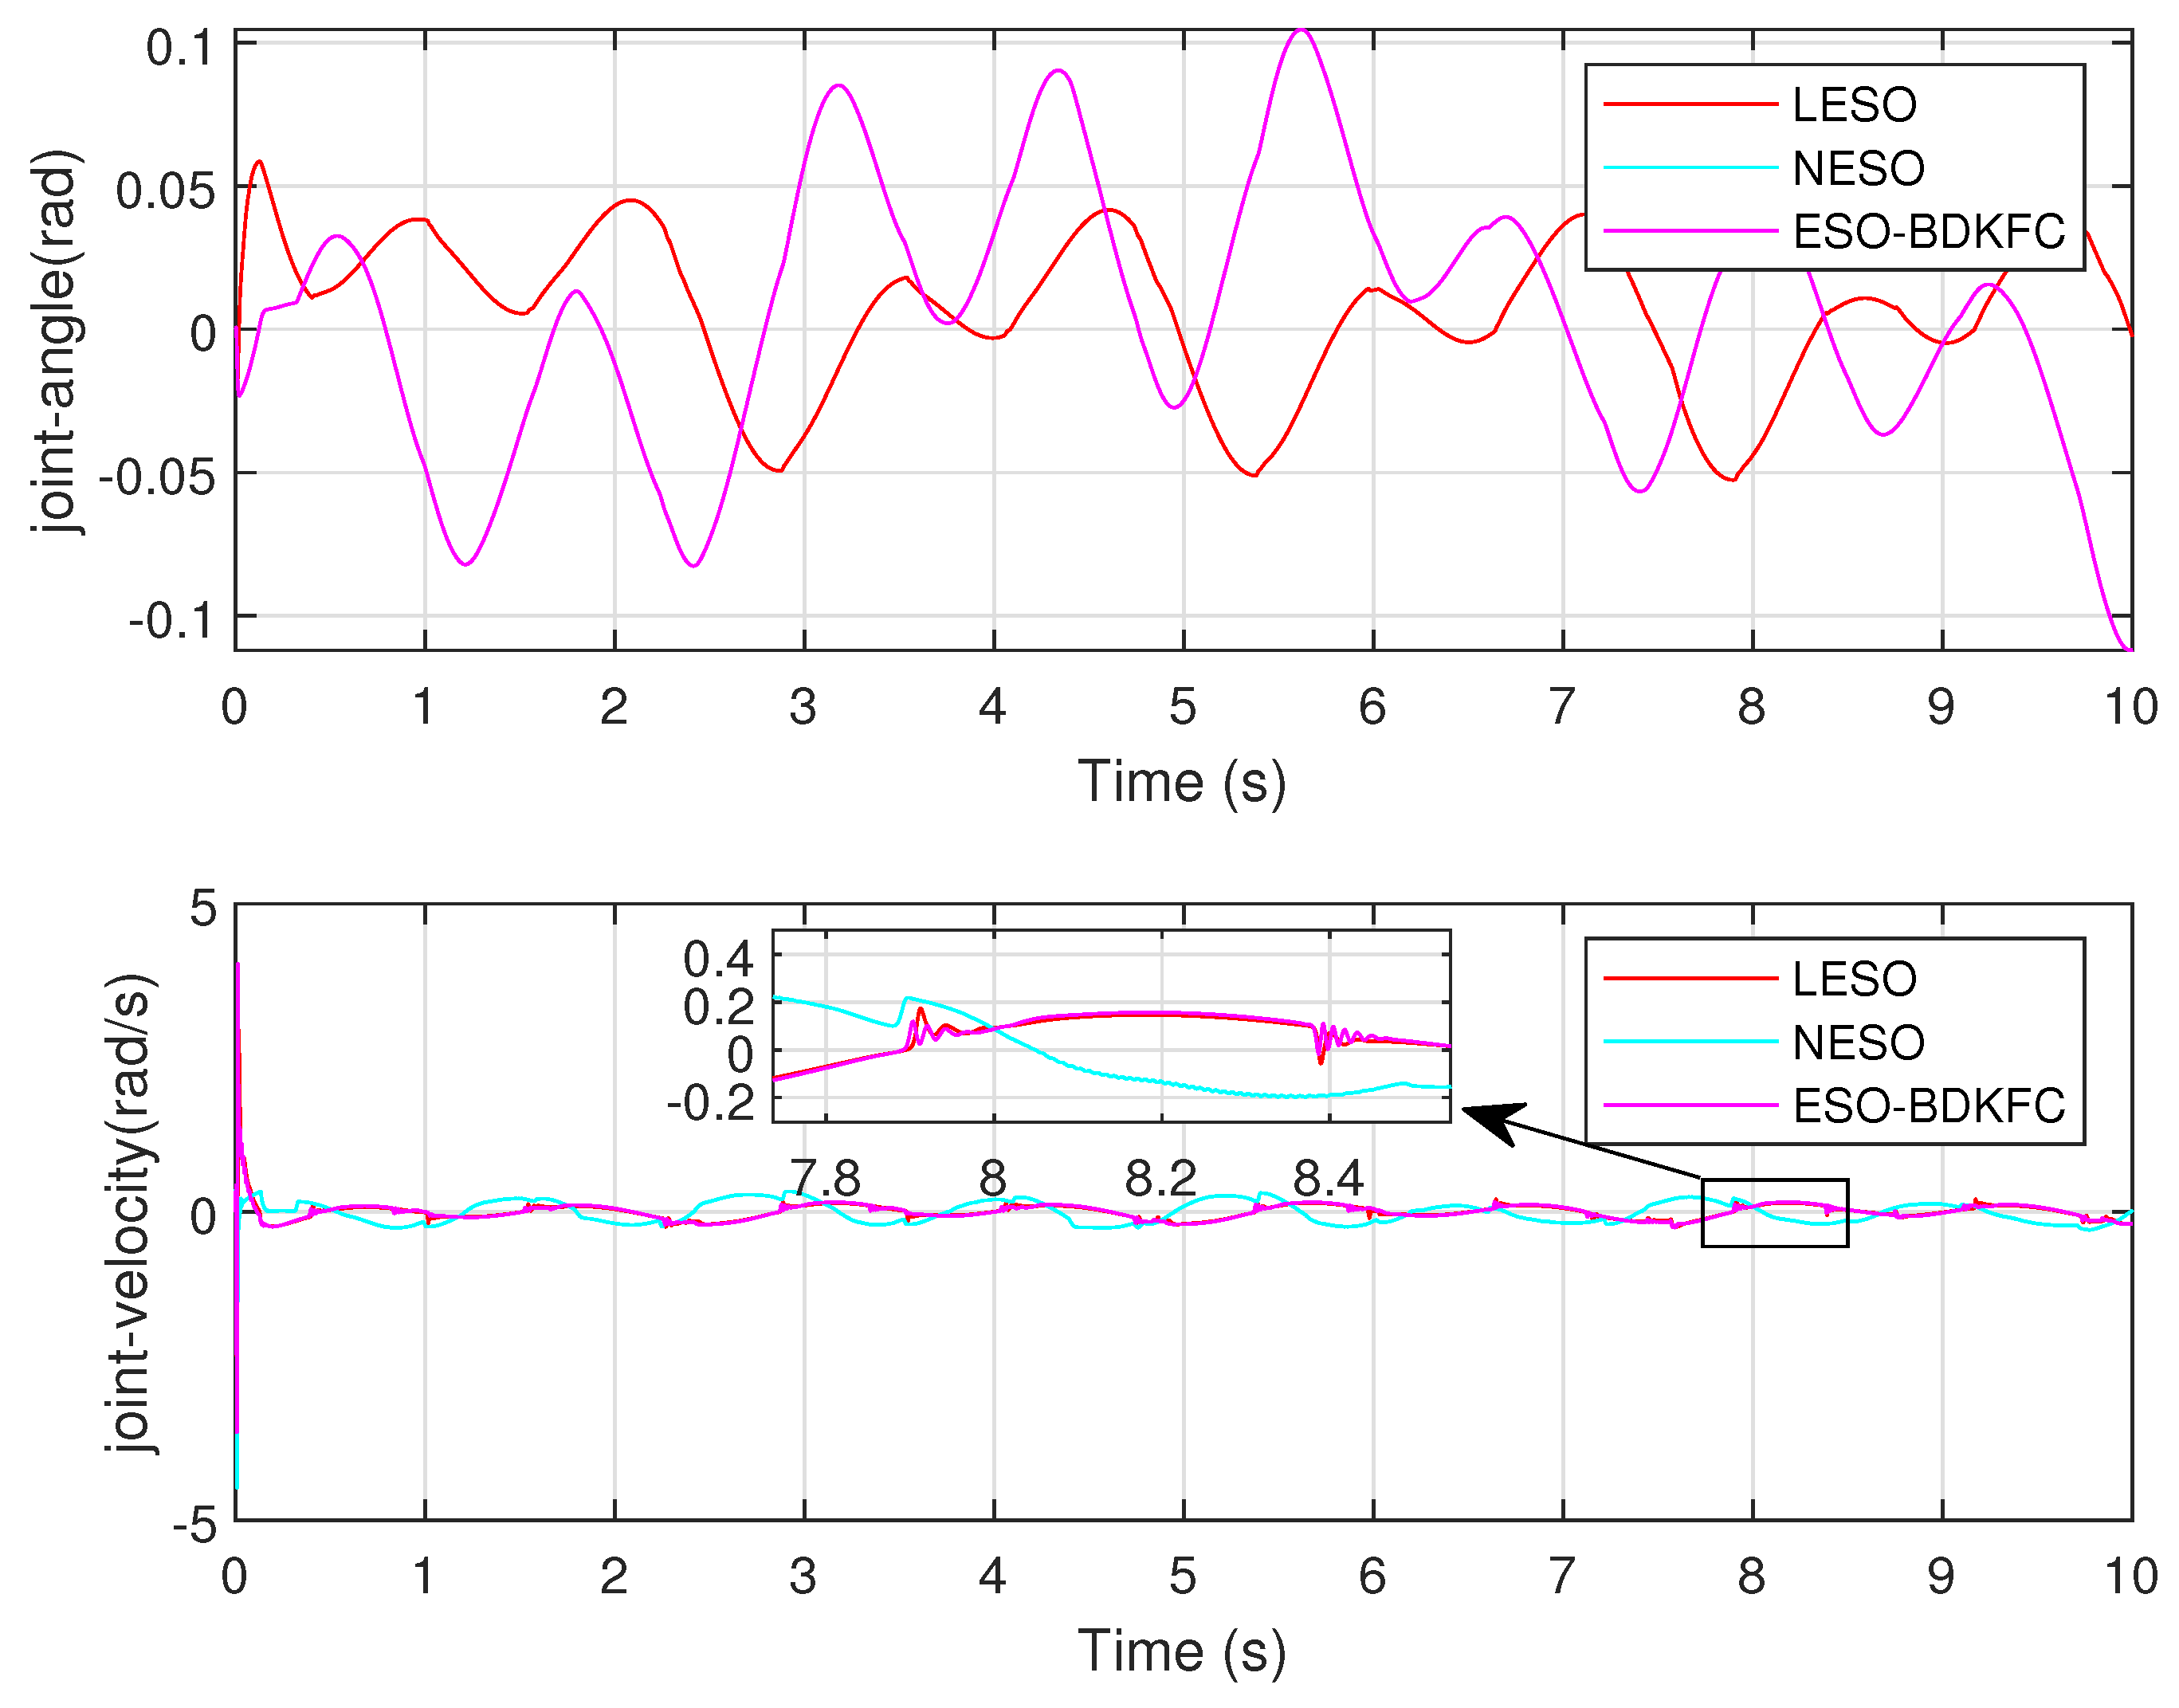
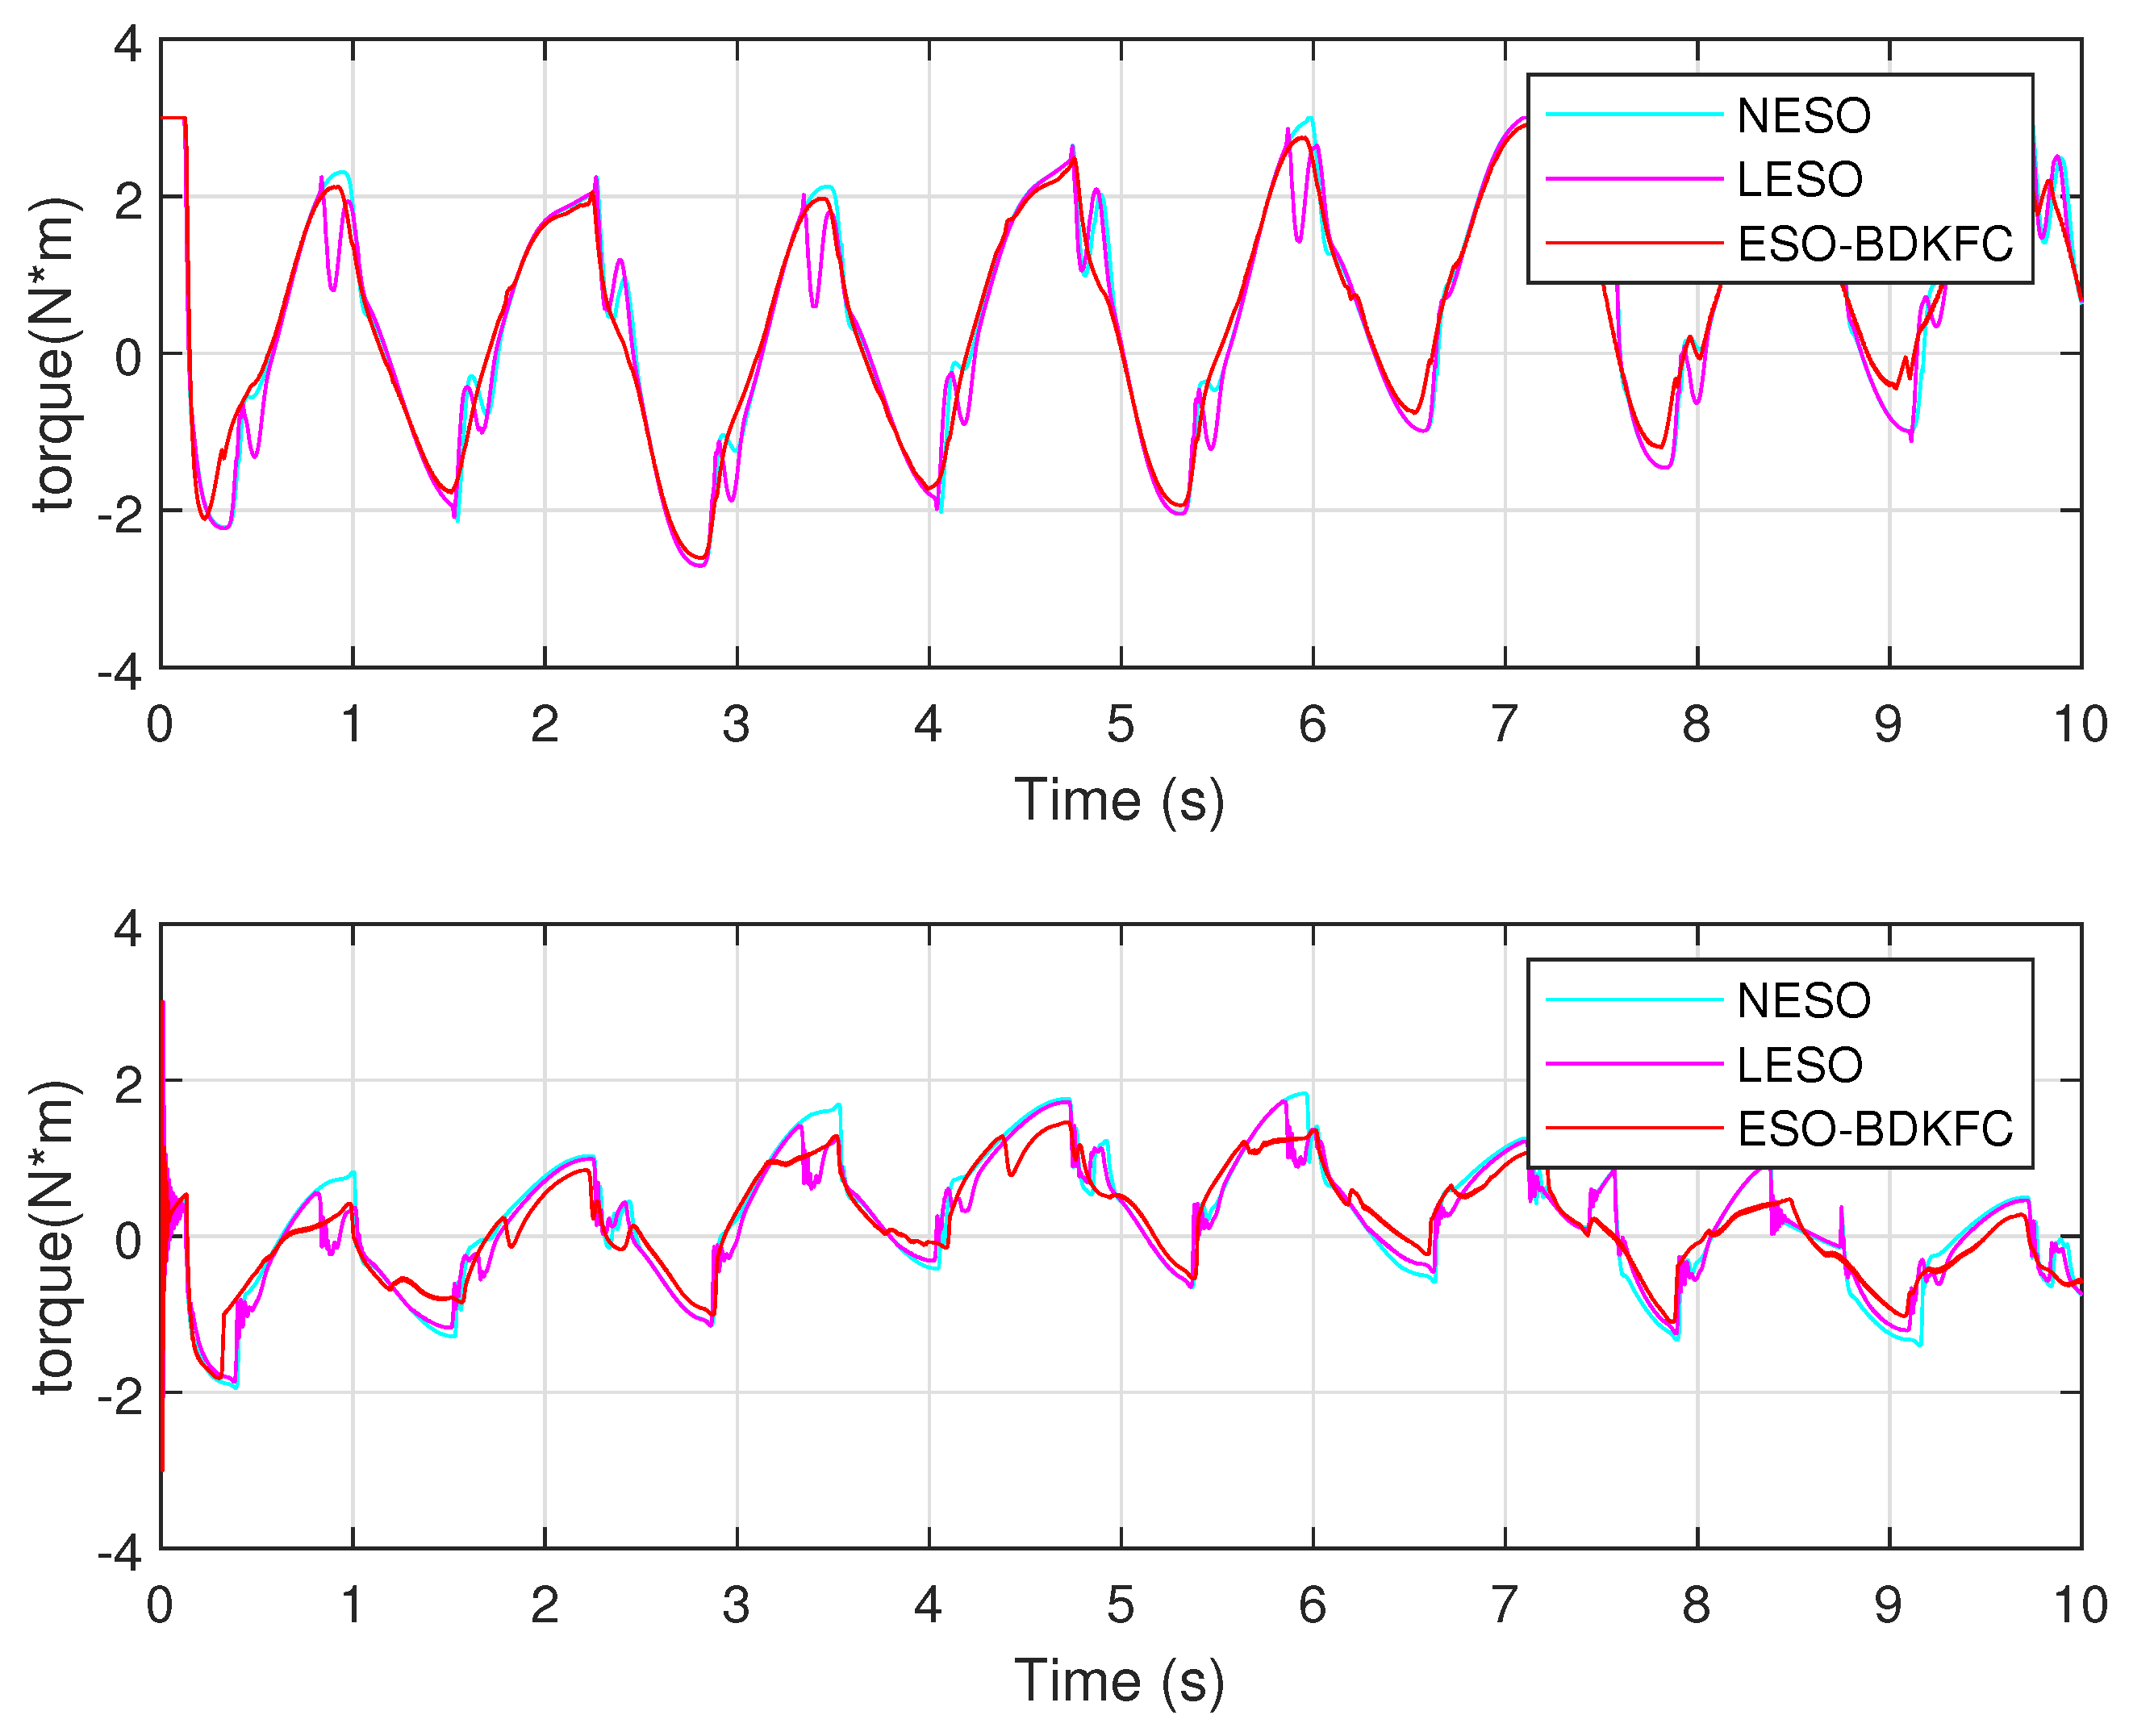
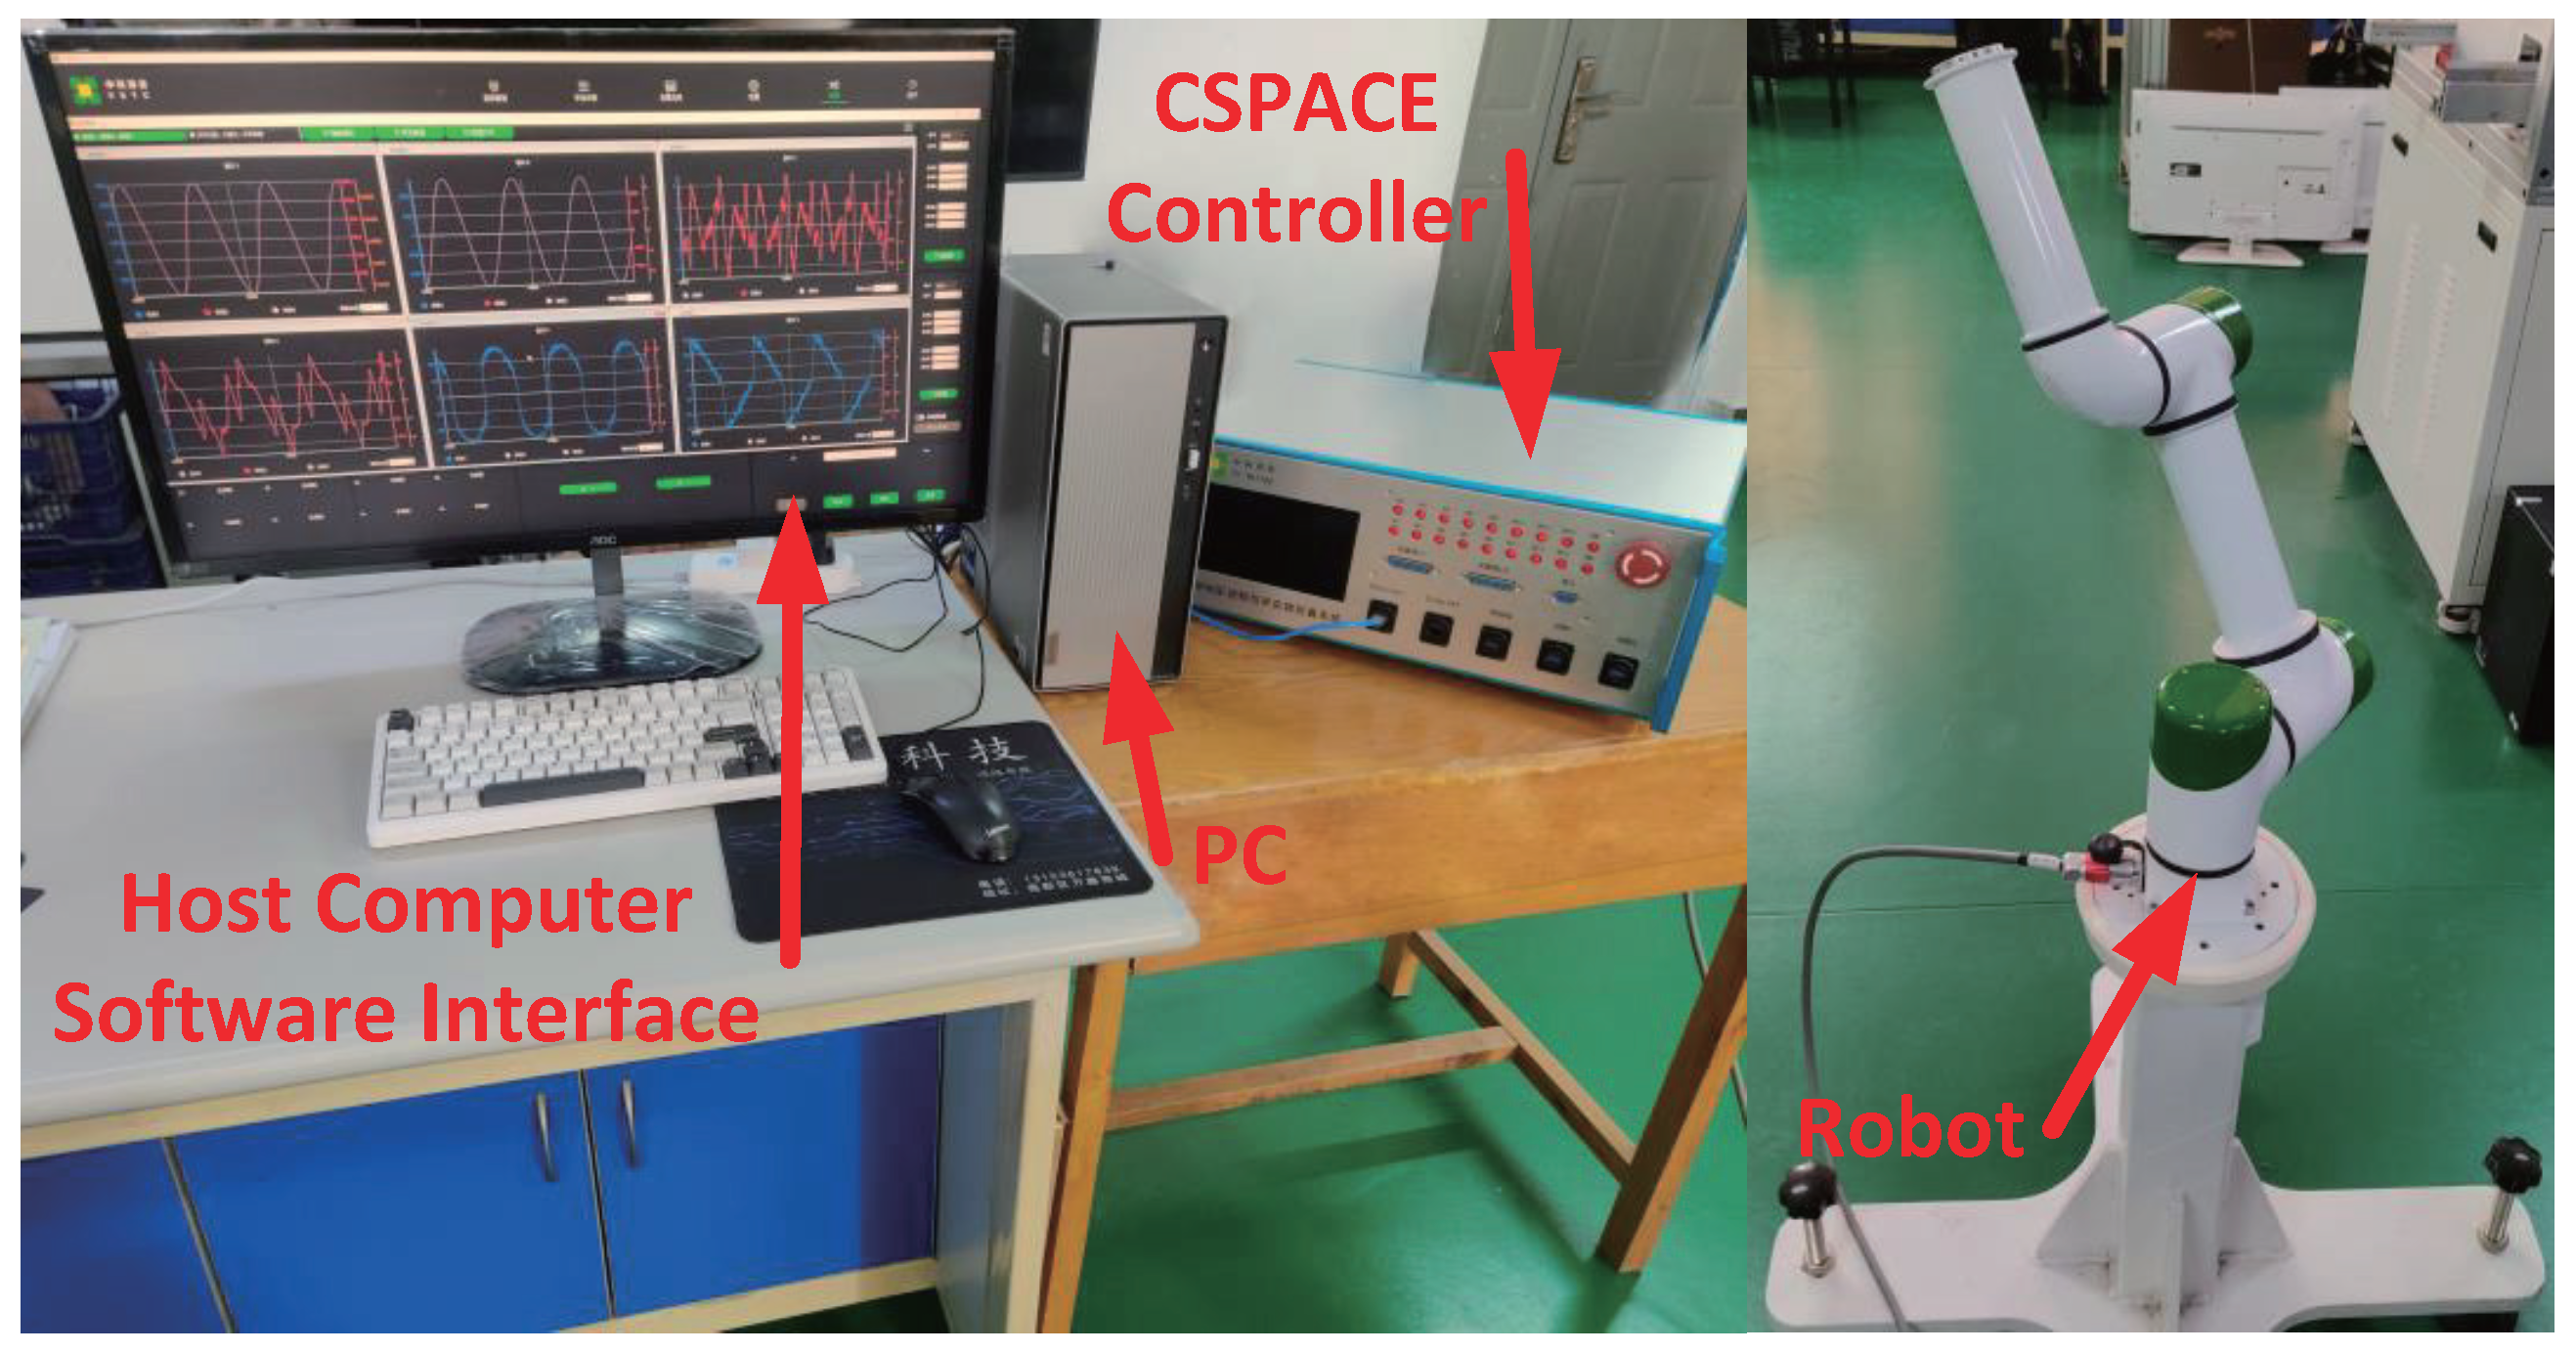
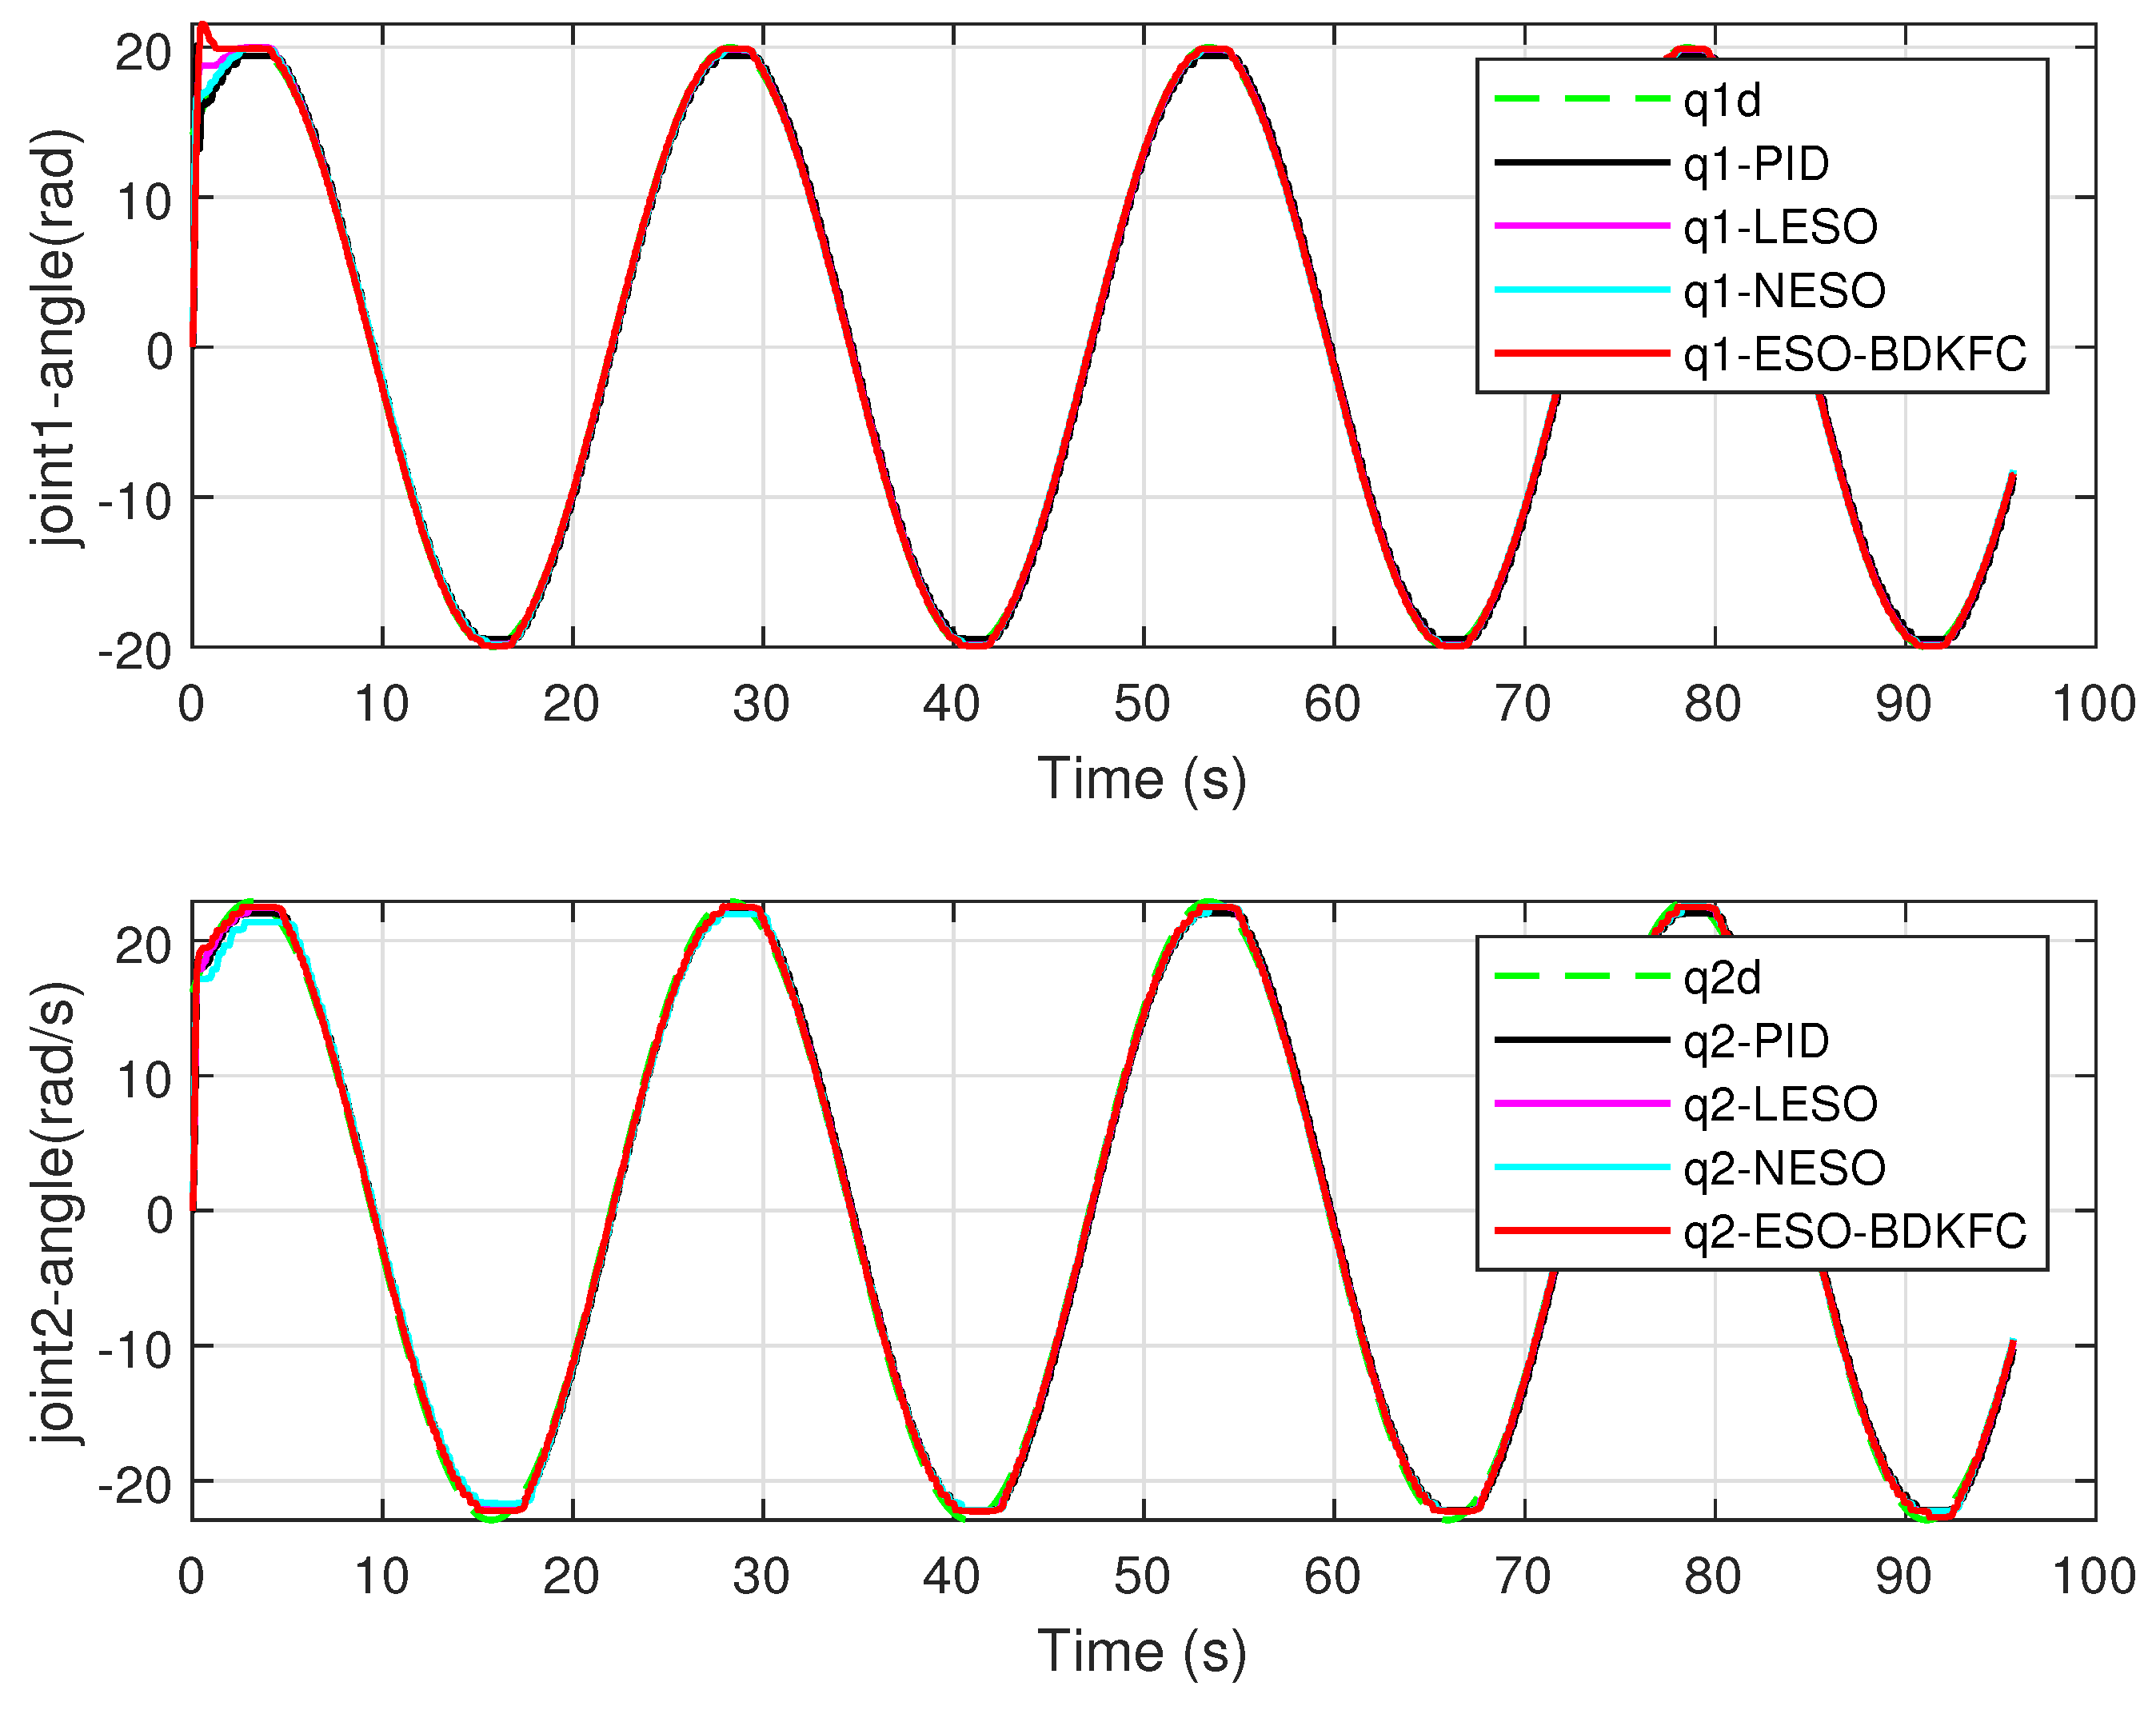
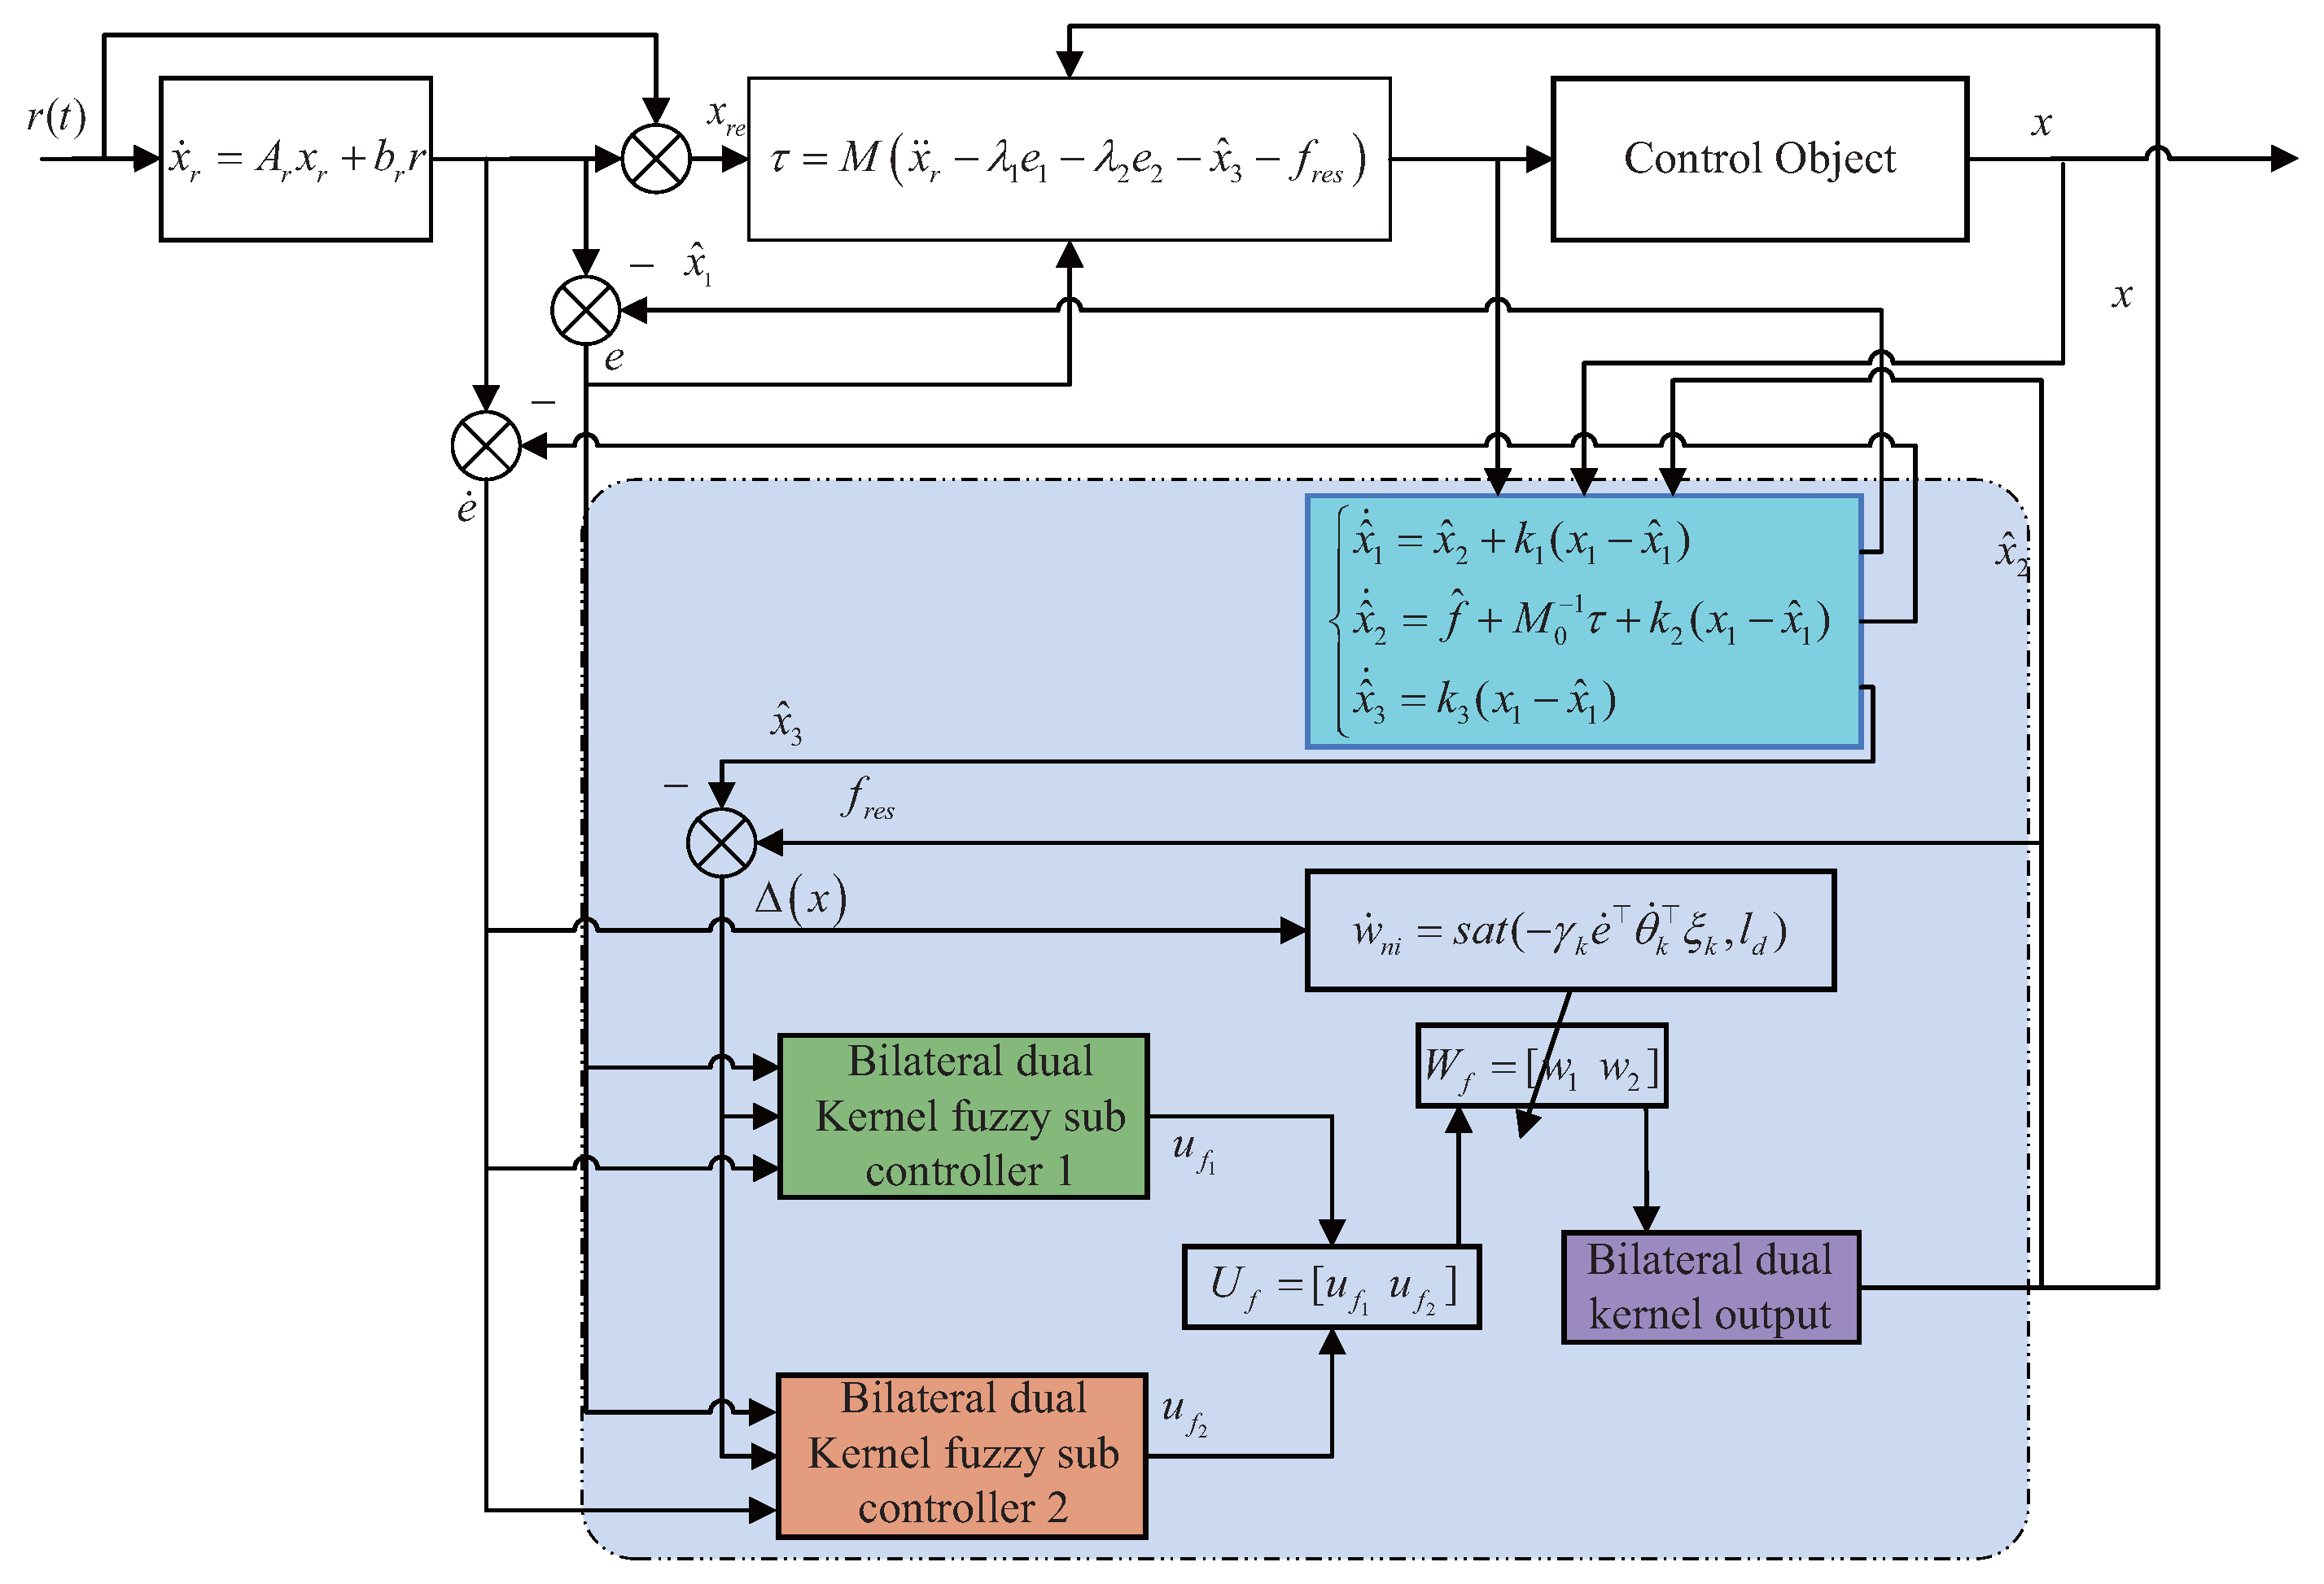
For nonlinear problems in robotic systems, such as parametric uncertainties and external disturbances, this paper proposes a control method based on bilateral dual-kernel fuzzy control. To address the issue that joint angular velocities cannot be directly measured, an extended state observer (ESO) is introduced to simultaneously estimate the joint positions, velocities, and system nonlinearities, thereby achieving effective reconstruction of the system states. In terms of controller design, a dual-kernel function is adopted instead of the conventional single-kernel function. By exploiting its enhanced feature representation capability and fast response characteristics, the proposed approach improves the system dynamic response speed and reduces the settling time. For nonlinear residuals, the bilateral parallel control strategy further improves the approximation accuracy of the control system. Multiple dual-kernel fuzzy sub-controllers are integrated in a bilateral parallel manner, and the weighting parameters of both the fuzzy system and the bilateral structure are updated in real time based on the approximation error. This enables accurate approximation and compensation of the residuals estimated by the extended state observer. The stability of the closed-loop system is rigorously proved based on Lyapunov theory. Finally, simulations on the MATLAB R2022b platform and experiments on a robotic experimental platform are conducted to verify that the proposed bilateral dual-kernel fuzzy controller achieves significantly improved control accuracy for a two-degree-of-freedom robotic manipulator system compared with conventional controllers, thereby demonstrating the effectiveness and superiority of the proposed algorithm.
Keywords: bilateral control strategy; bilateral dual-kernel fuzzy controller; extended state observer; nonlinear control; two-degree-of-freedom manipulator bilateral control strategy; bilateral dual-kernel fuzzy controller; extended state observer; nonlinear control; two-degree-of-freedom manipulator