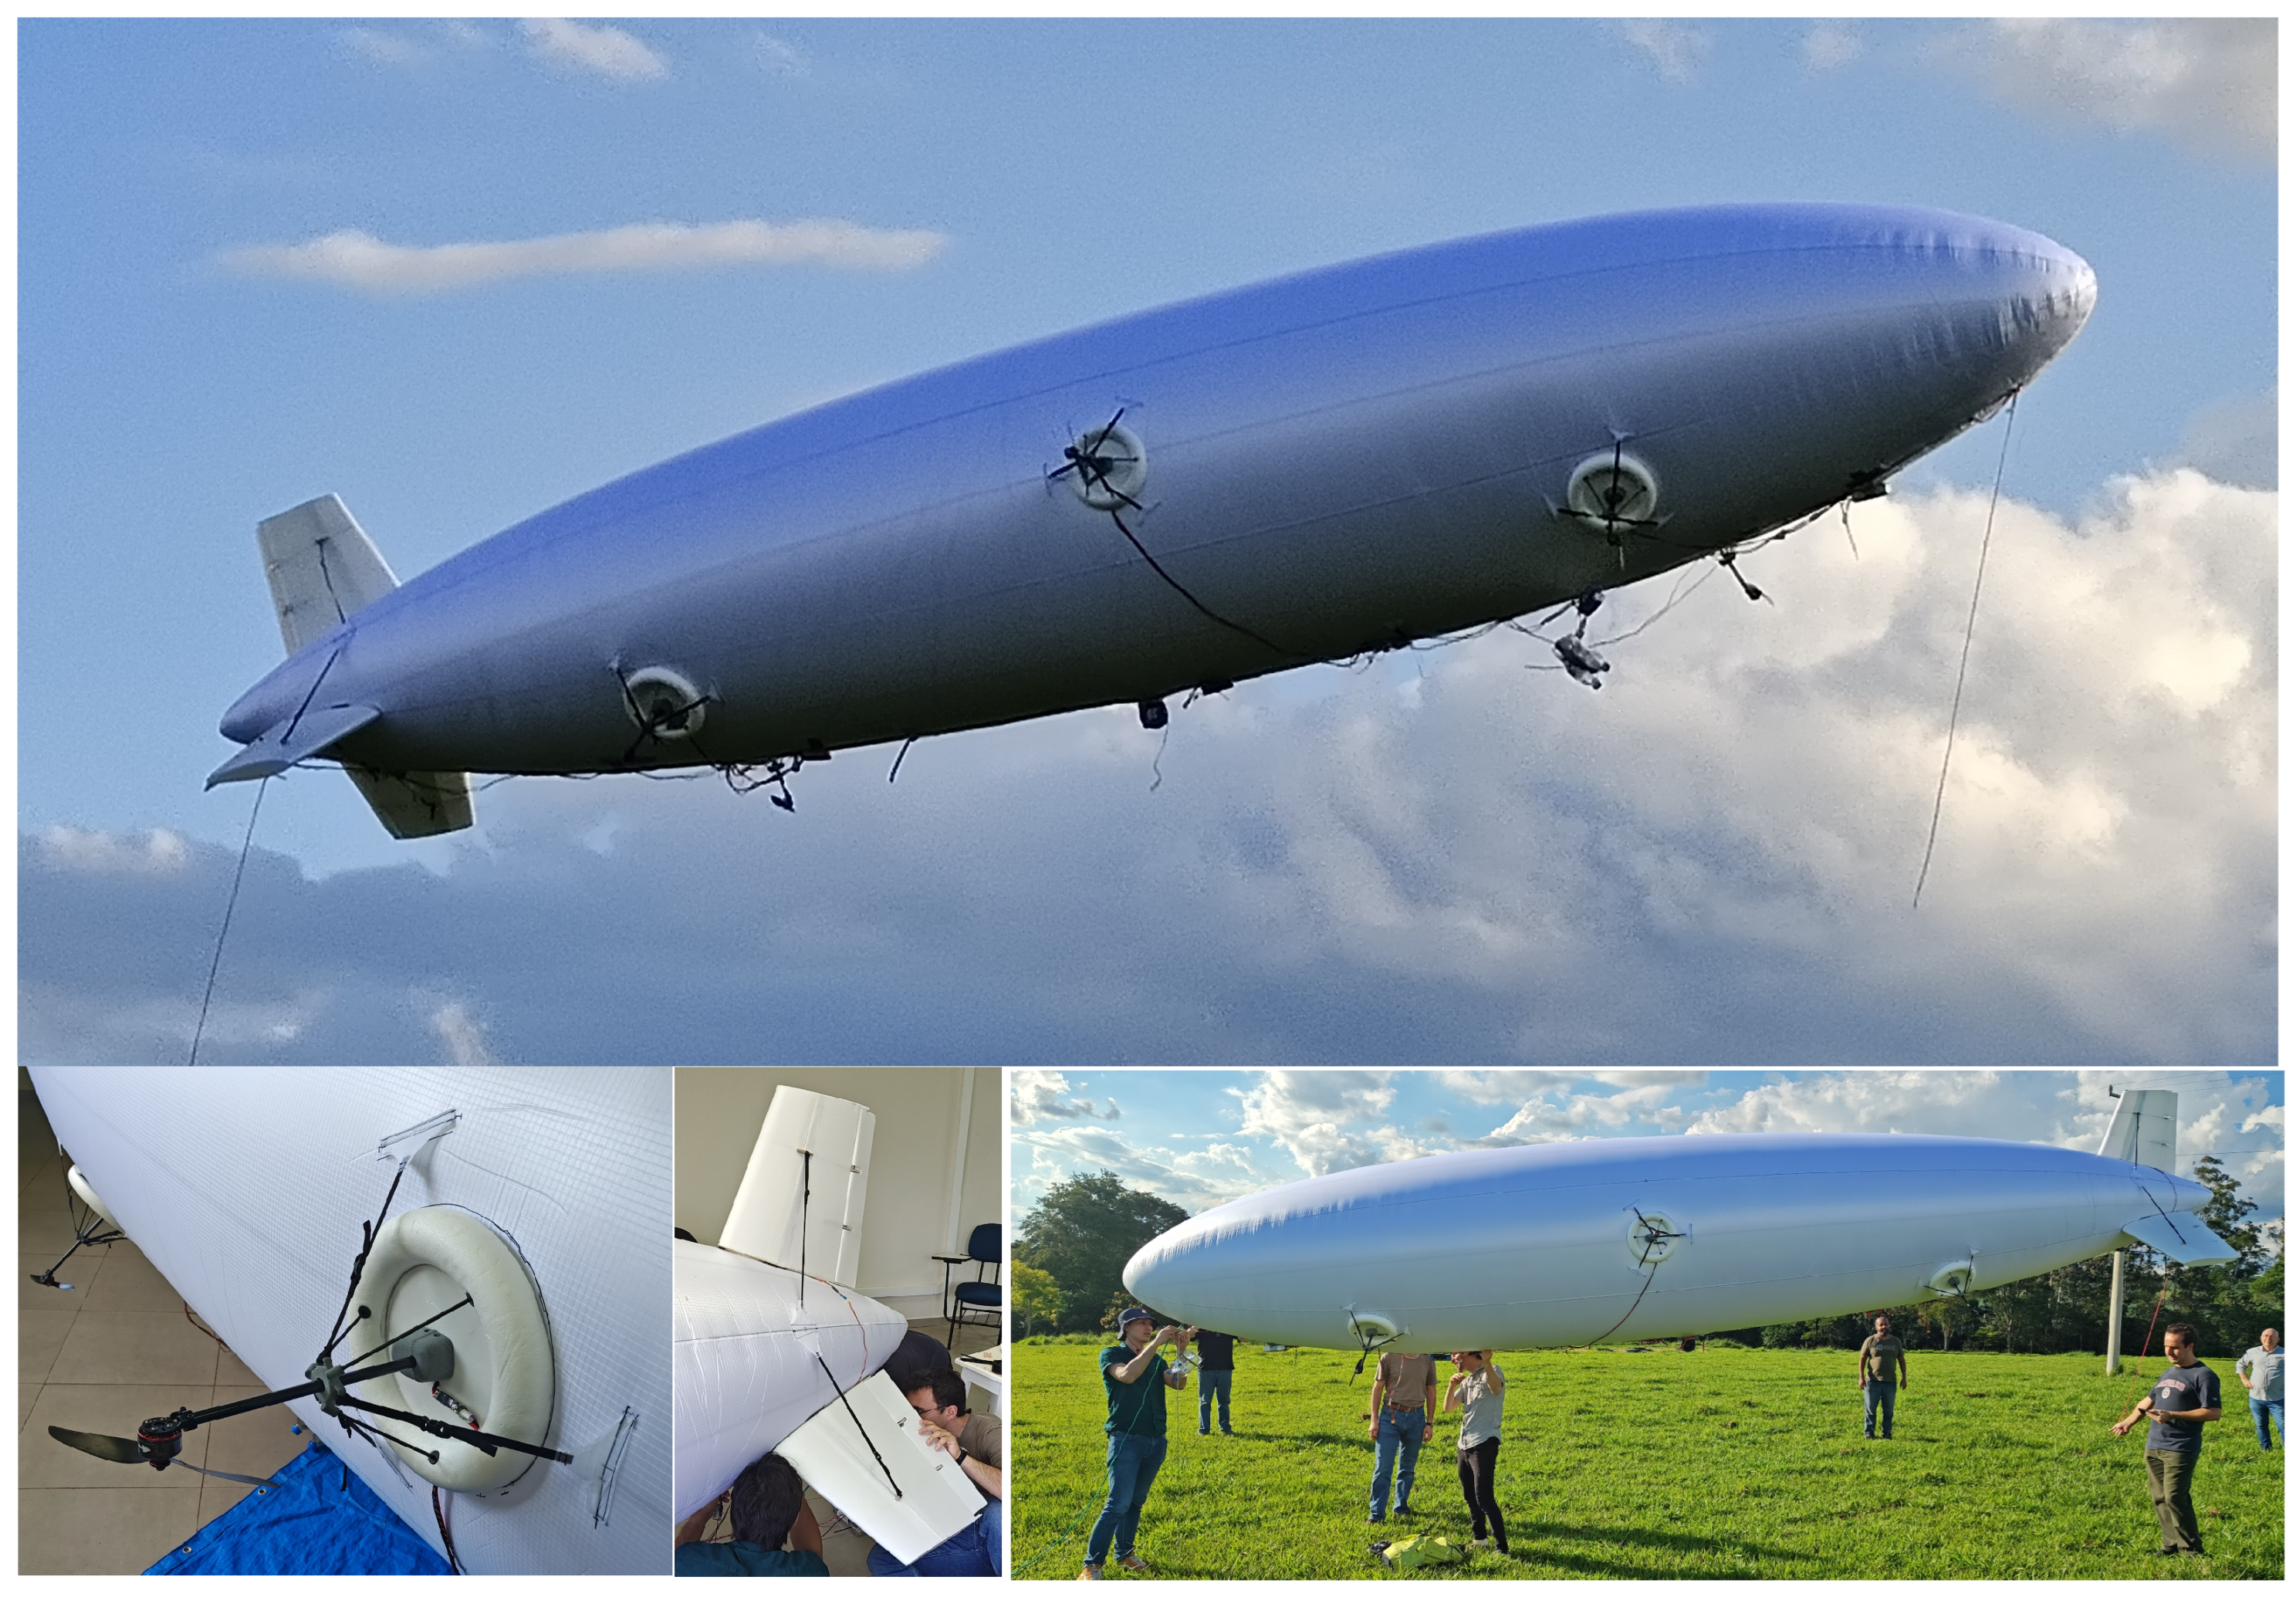
Hexa-Propeller Airship for Environmental Surveillance and Monitoring in Amazon Rainforest


Abstract
Share and Cite
Azinheira, J.; Carvalho, R.; Paiva, E.; Cordeiro, R. Hexa-Propeller Airship for Environmental Surveillance and Monitoring in Amazon Rainforest. Aerospace 2024, 11, 249. https://doi.org/10.3390/aerospace11040249
Azinheira J, Carvalho R, Paiva E, Cordeiro R. Hexa-Propeller Airship for Environmental Surveillance and Monitoring in Amazon Rainforest. Aerospace. 2024; 11(4):249. https://doi.org/10.3390/aerospace11040249
Chicago/Turabian StyleAzinheira, José, Reginaldo Carvalho, Ely Paiva, and Rafael Cordeiro. 2024. "Hexa-Propeller Airship for Environmental Surveillance and Monitoring in Amazon Rainforest" Aerospace 11, no. 4: 249. https://doi.org/10.3390/aerospace11040249
APA StyleAzinheira, J., Carvalho, R., Paiva, E., & Cordeiro, R. (2024). Hexa-Propeller Airship for Environmental Surveillance and Monitoring in Amazon Rainforest. Aerospace, 11(4), 249. https://doi.org/10.3390/aerospace11040249