Article

Deadlock-Free Planner for Occluded Intersections Using Estimated Visibility of Hidden Vehicles †
1
Graduate School of Informatics, Nagoya University, Nagoya 464-8603, Japan
2
Tier IV, Inc., JR Gate Tower, 1-1-3 Meieki Nakamura-ku, Nagoya 450-6627, Japan
*
Author to whom correspondence should be addressed.
This paper is an extended version of our paper published in 2019 IEEE Intelligent Transportation Systems Conference under the title “Crossing Blind Intersections from a Full Stop Using Estimated Visibility of Approaching Vehicles”.
Electronics 2021, 10(4), 411; https://doi.org/10.3390/electronics10040411

Submission received: 26 December 2020 / Revised: 30 January 2021 / Accepted: 3 February 2021 / Published: 8 February 2021
(This article belongs to the Special Issue Autonomous Vehicles Technology)

Abstract

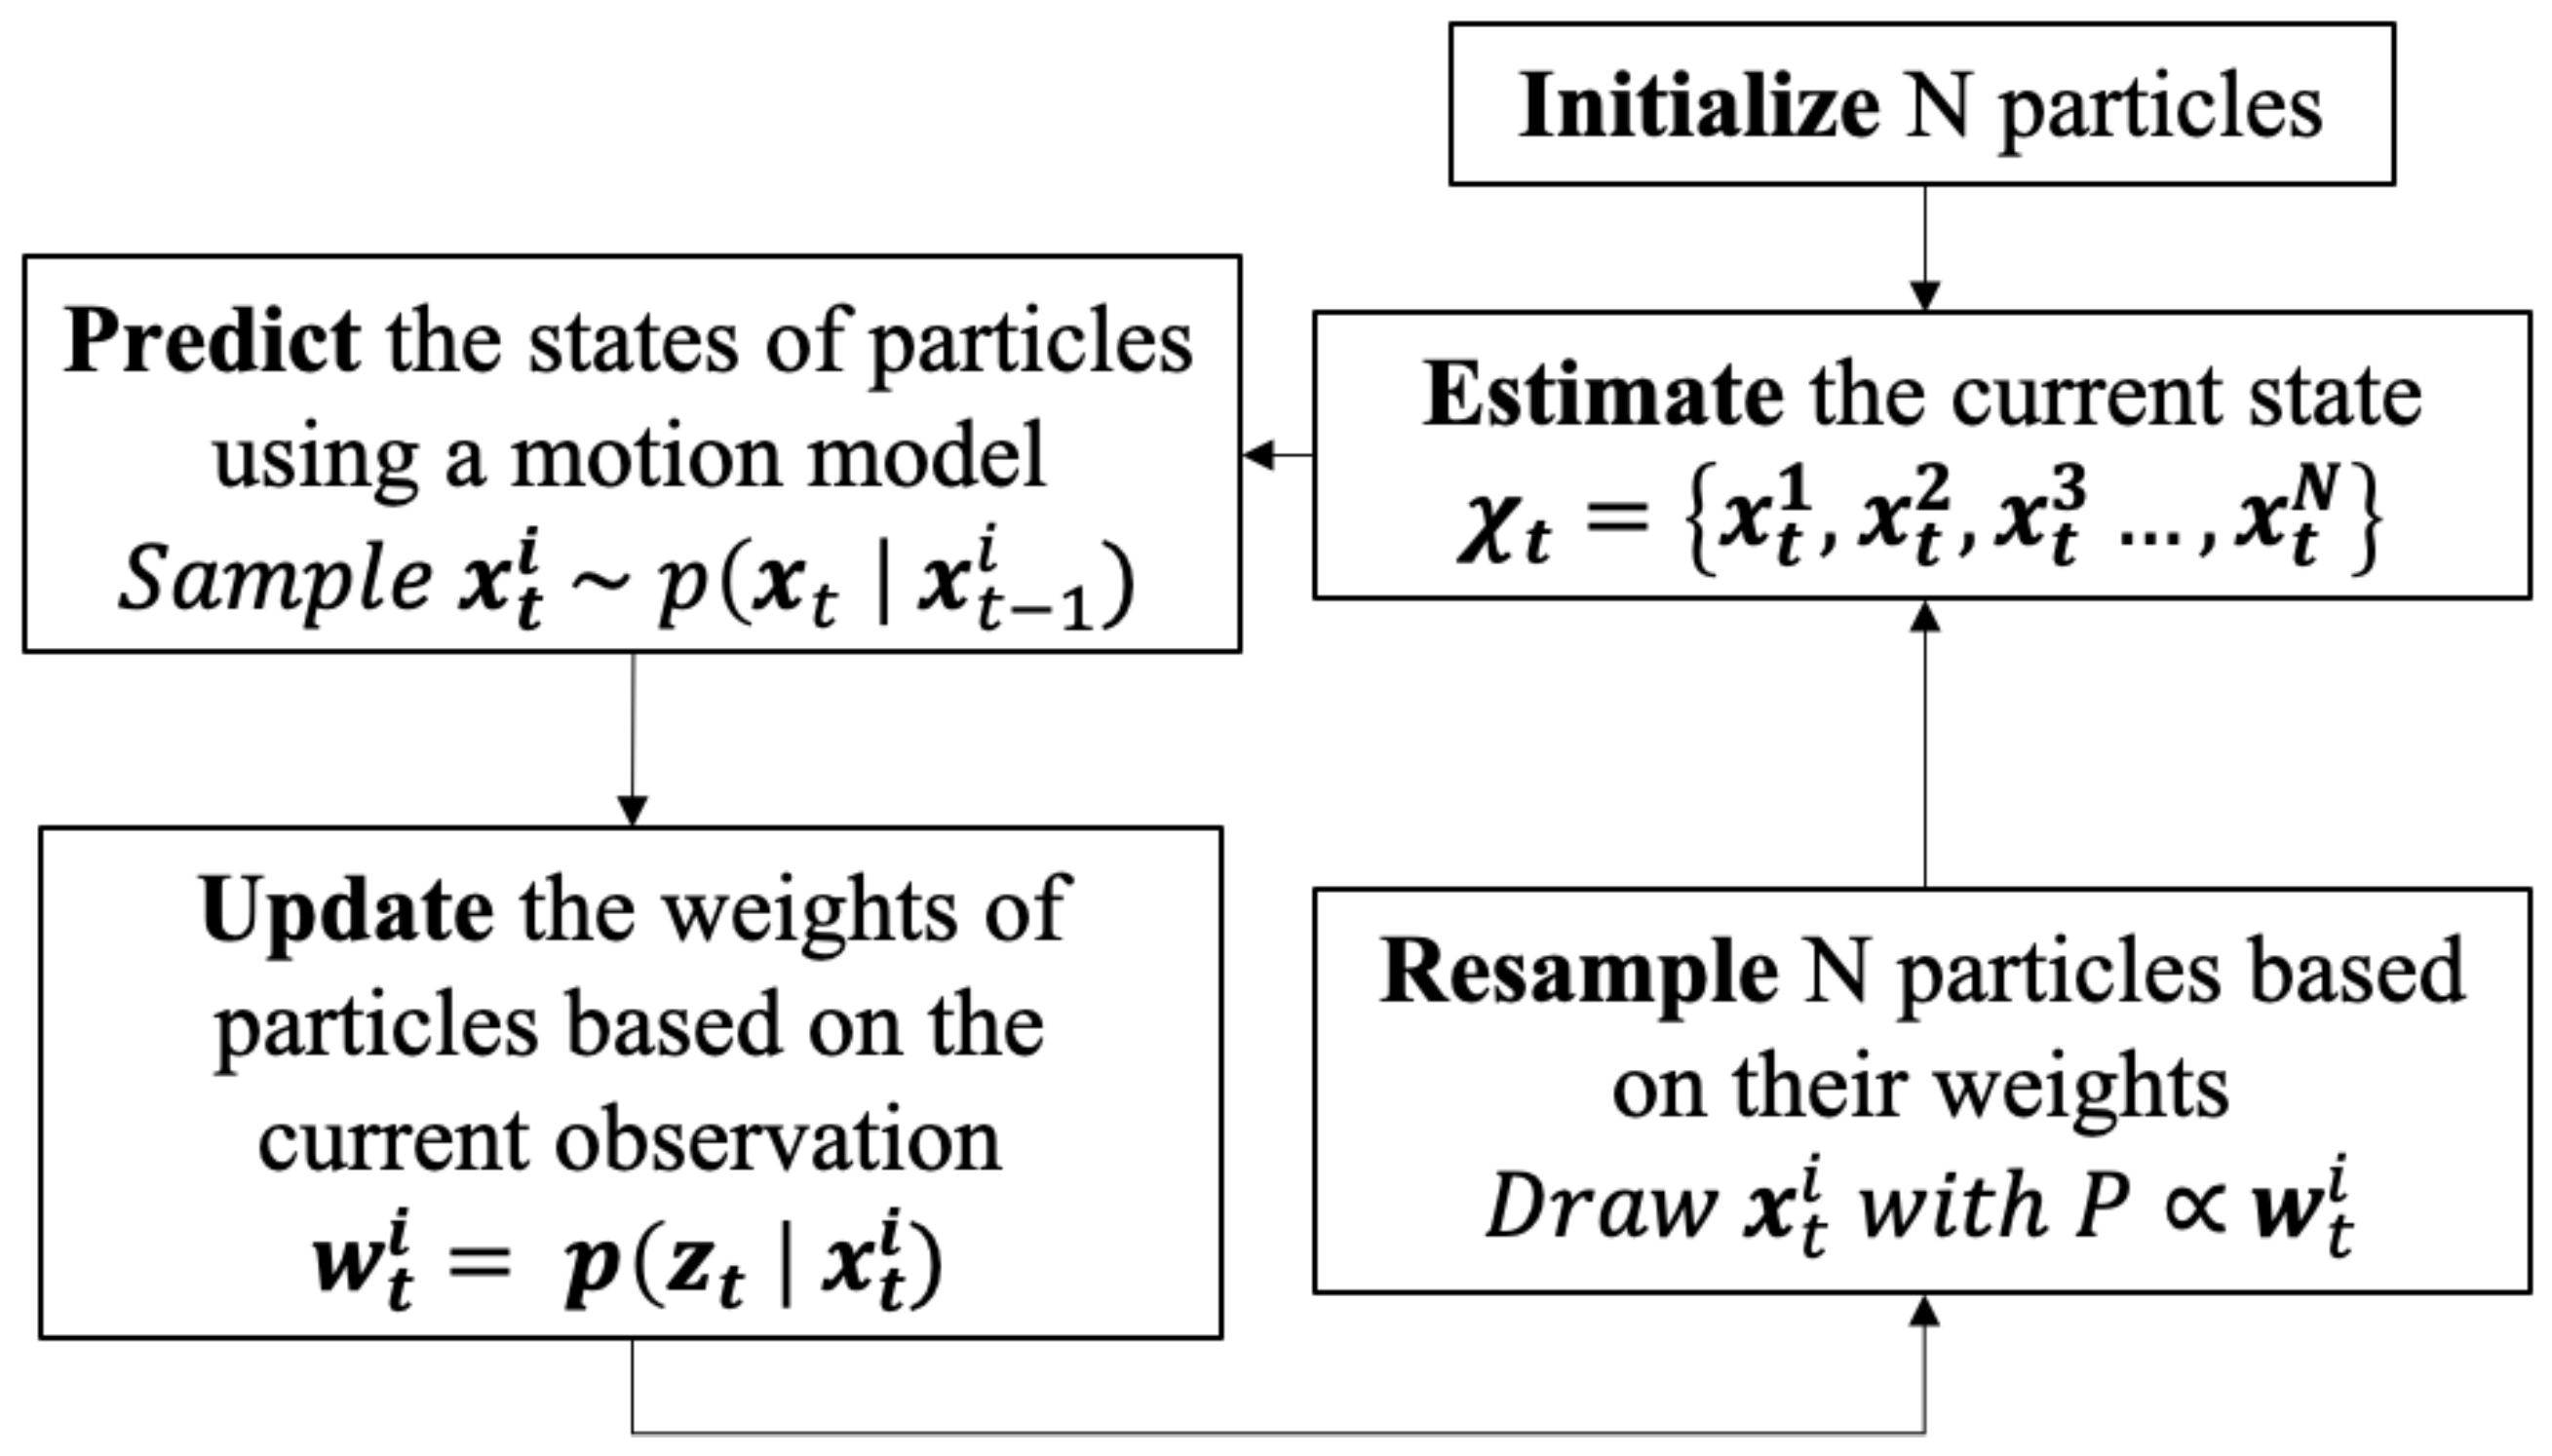
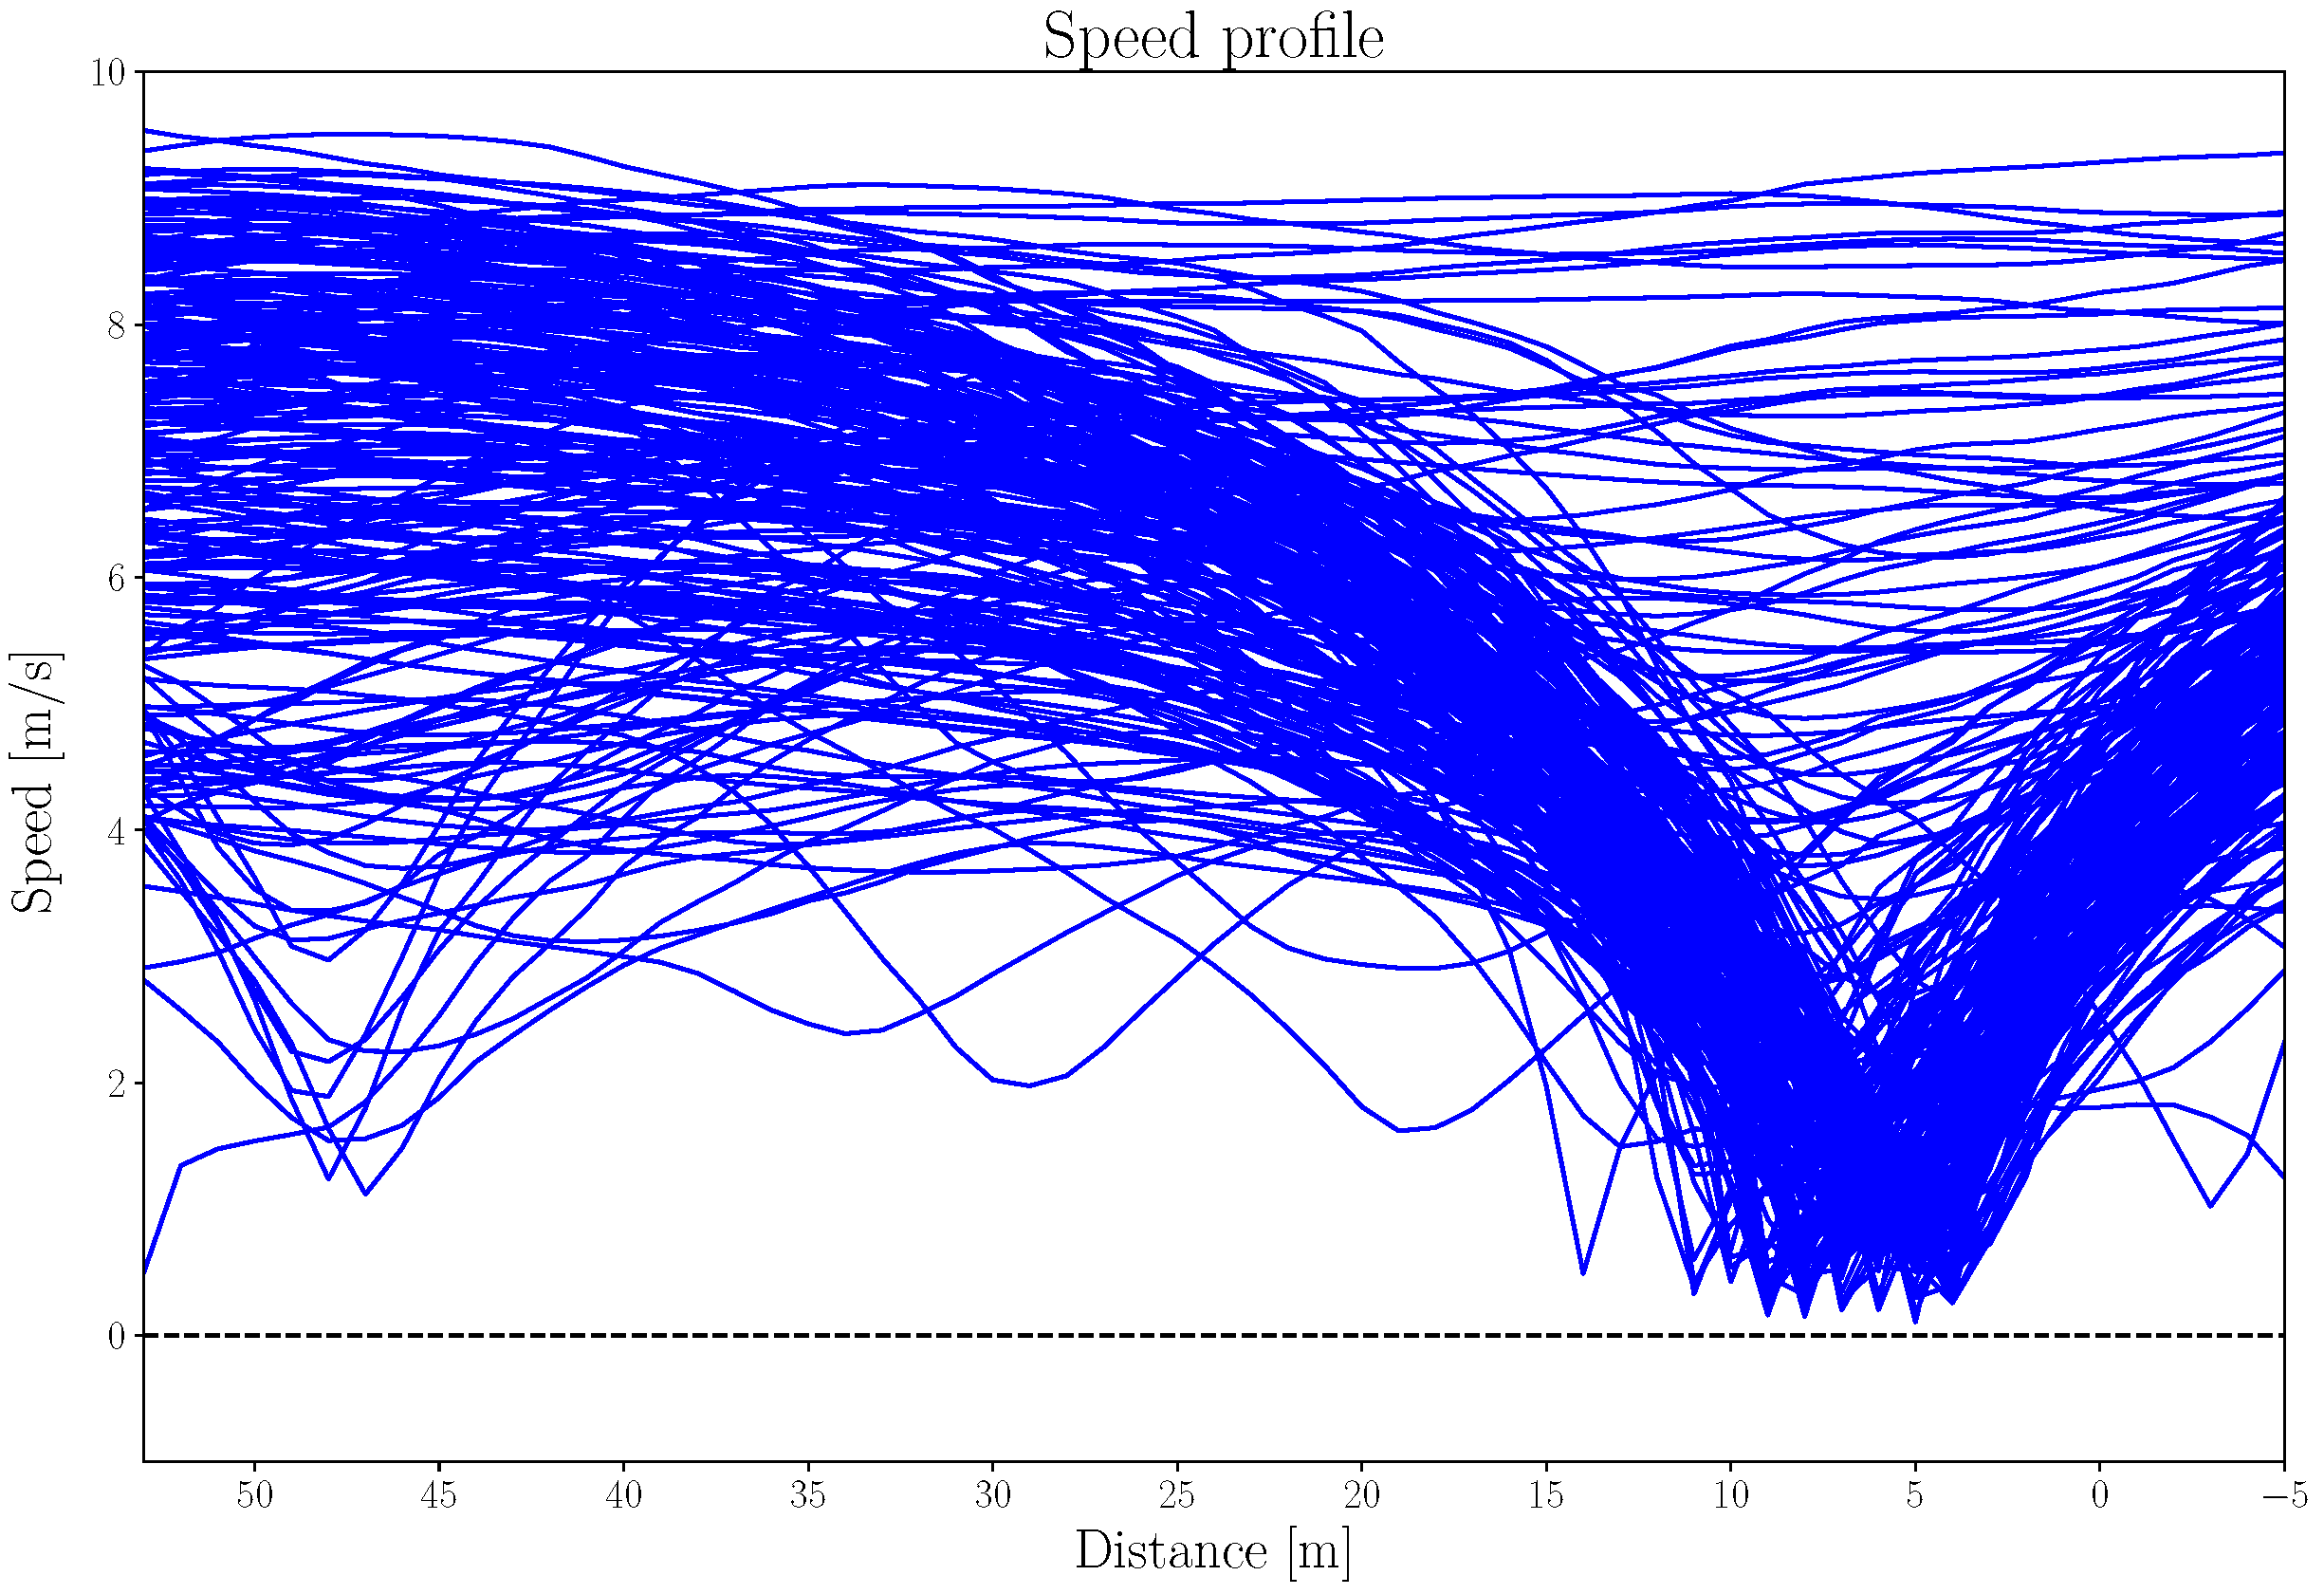
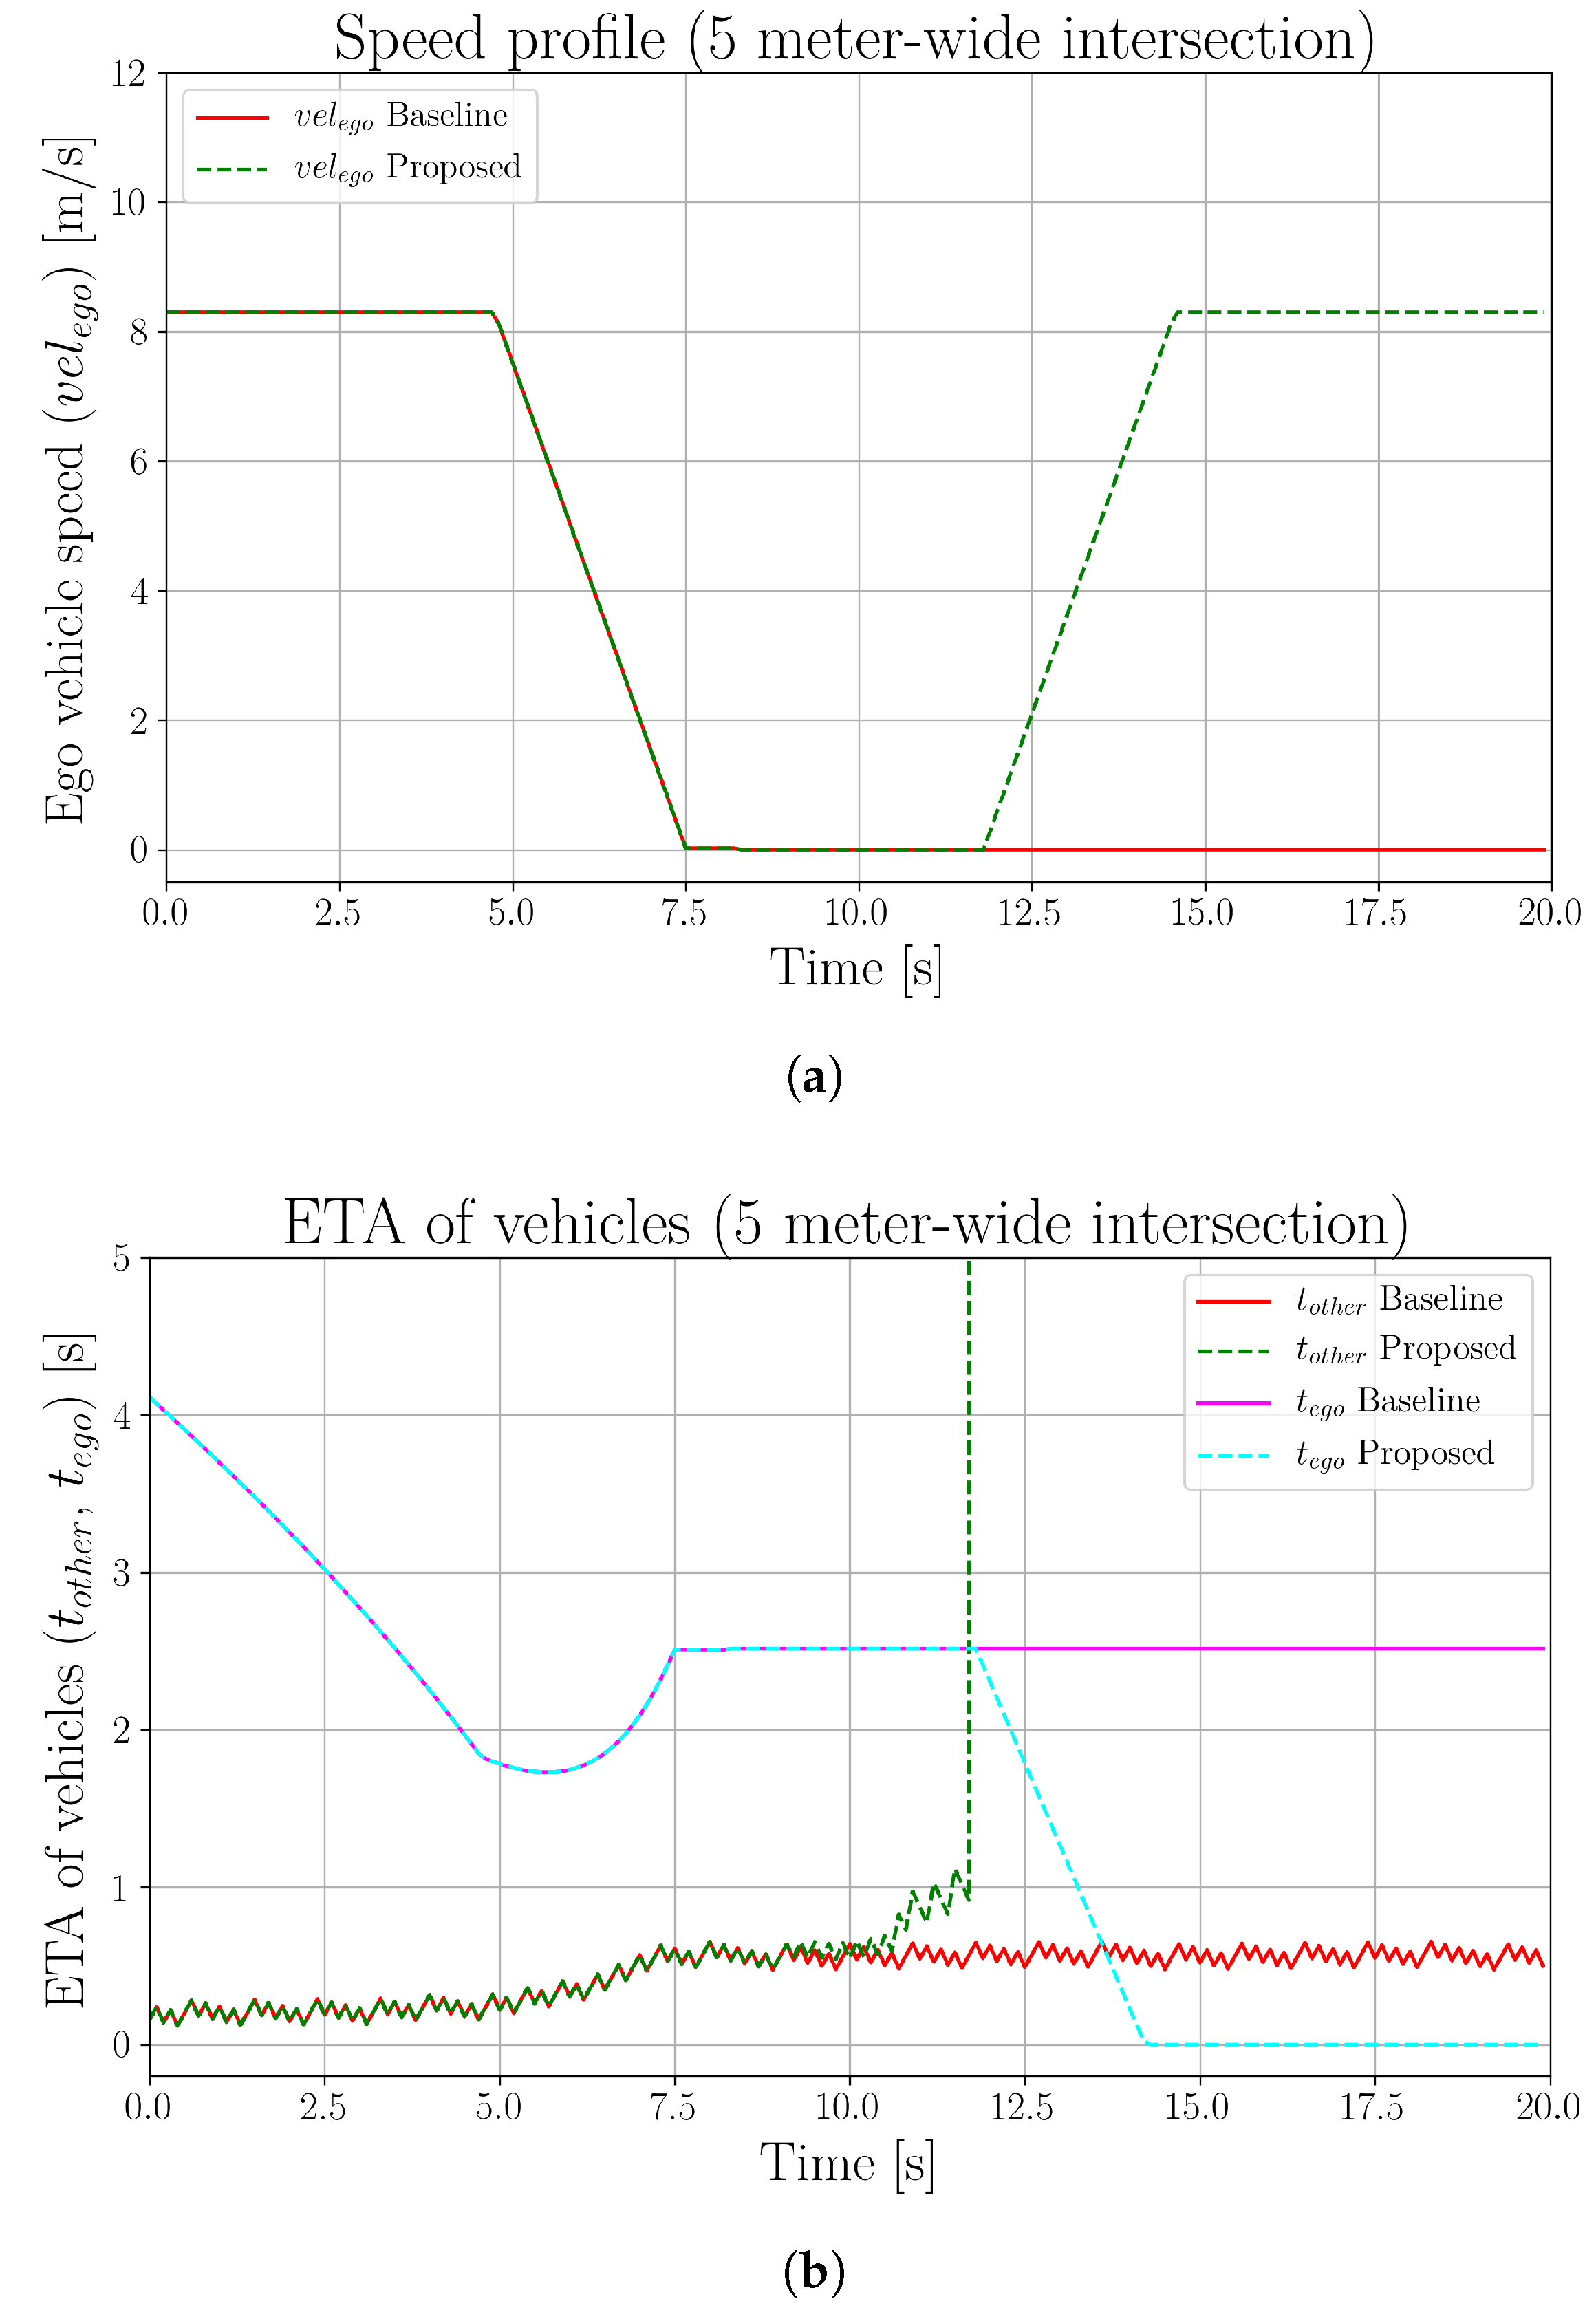
A common approach used for planning blind intersection crossings is to assume that hypothetical vehicles are approaching the intersection at a constant speed from the occluded areas. Such an assumption can result in a deadlock problem, causing the ego vehicle to remain stopped at an intersection indefinitely due to insufficient visibility. To solve this problem and facilitate safe, deadlock-free intersection crossing, we propose a blind intersection planner that utilizes both the ego vehicle and the approaching vehicle’s visibility. The planner uses a particle filter and our proposed visibility-dependent behavior model of approaching vehicles for predicting hidden vehicles. The behavior model is designed based on an analysis of actual driving data from multiple drivers crossing blind intersections. The proposed planner was tested in a simulation and found to be effective for allowing deadlock-free crossings at intersections where a baseline planner became stuck in a deadlock. The effects of perception accuracy and sensor position on output motion were also investigated. It was found that the proposed planner delayed crossing motion when the perception was imperfect. Furthermore, our results showed that the planner decelerated less while crossing the intersection with the front-mounted sensor configuration compared to the roof-mounted configuration due to the improved visibility. The minimum speed difference between the two sensor configurations was 1.82 m/s at an intersection with relatively poor visibility and 1.50 m/s at an intersection with good visibility.
Keywords: autonomous vehicle; autonomous driving; visibility; occlusion; driving behavior; uncertainty; perception; motion planning; intersection crossing autonomous vehicle; autonomous driving; visibility; occlusion; driving behavior; uncertainty; perception; motion planning; intersection crossing