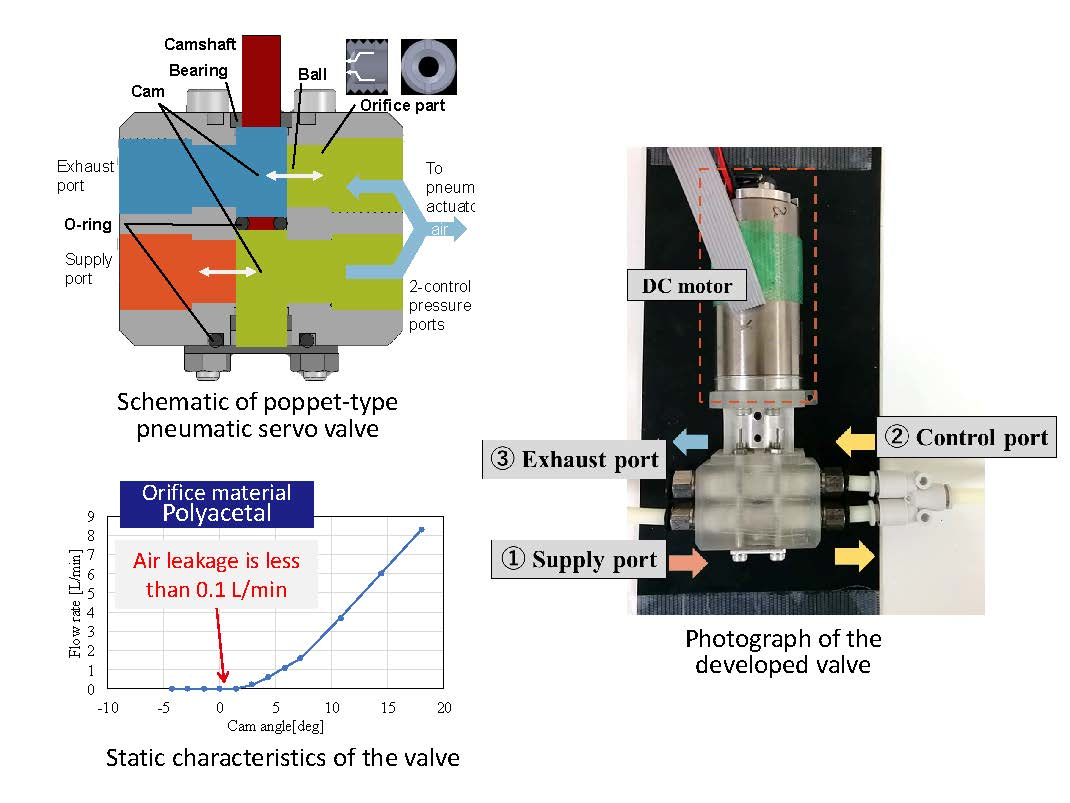
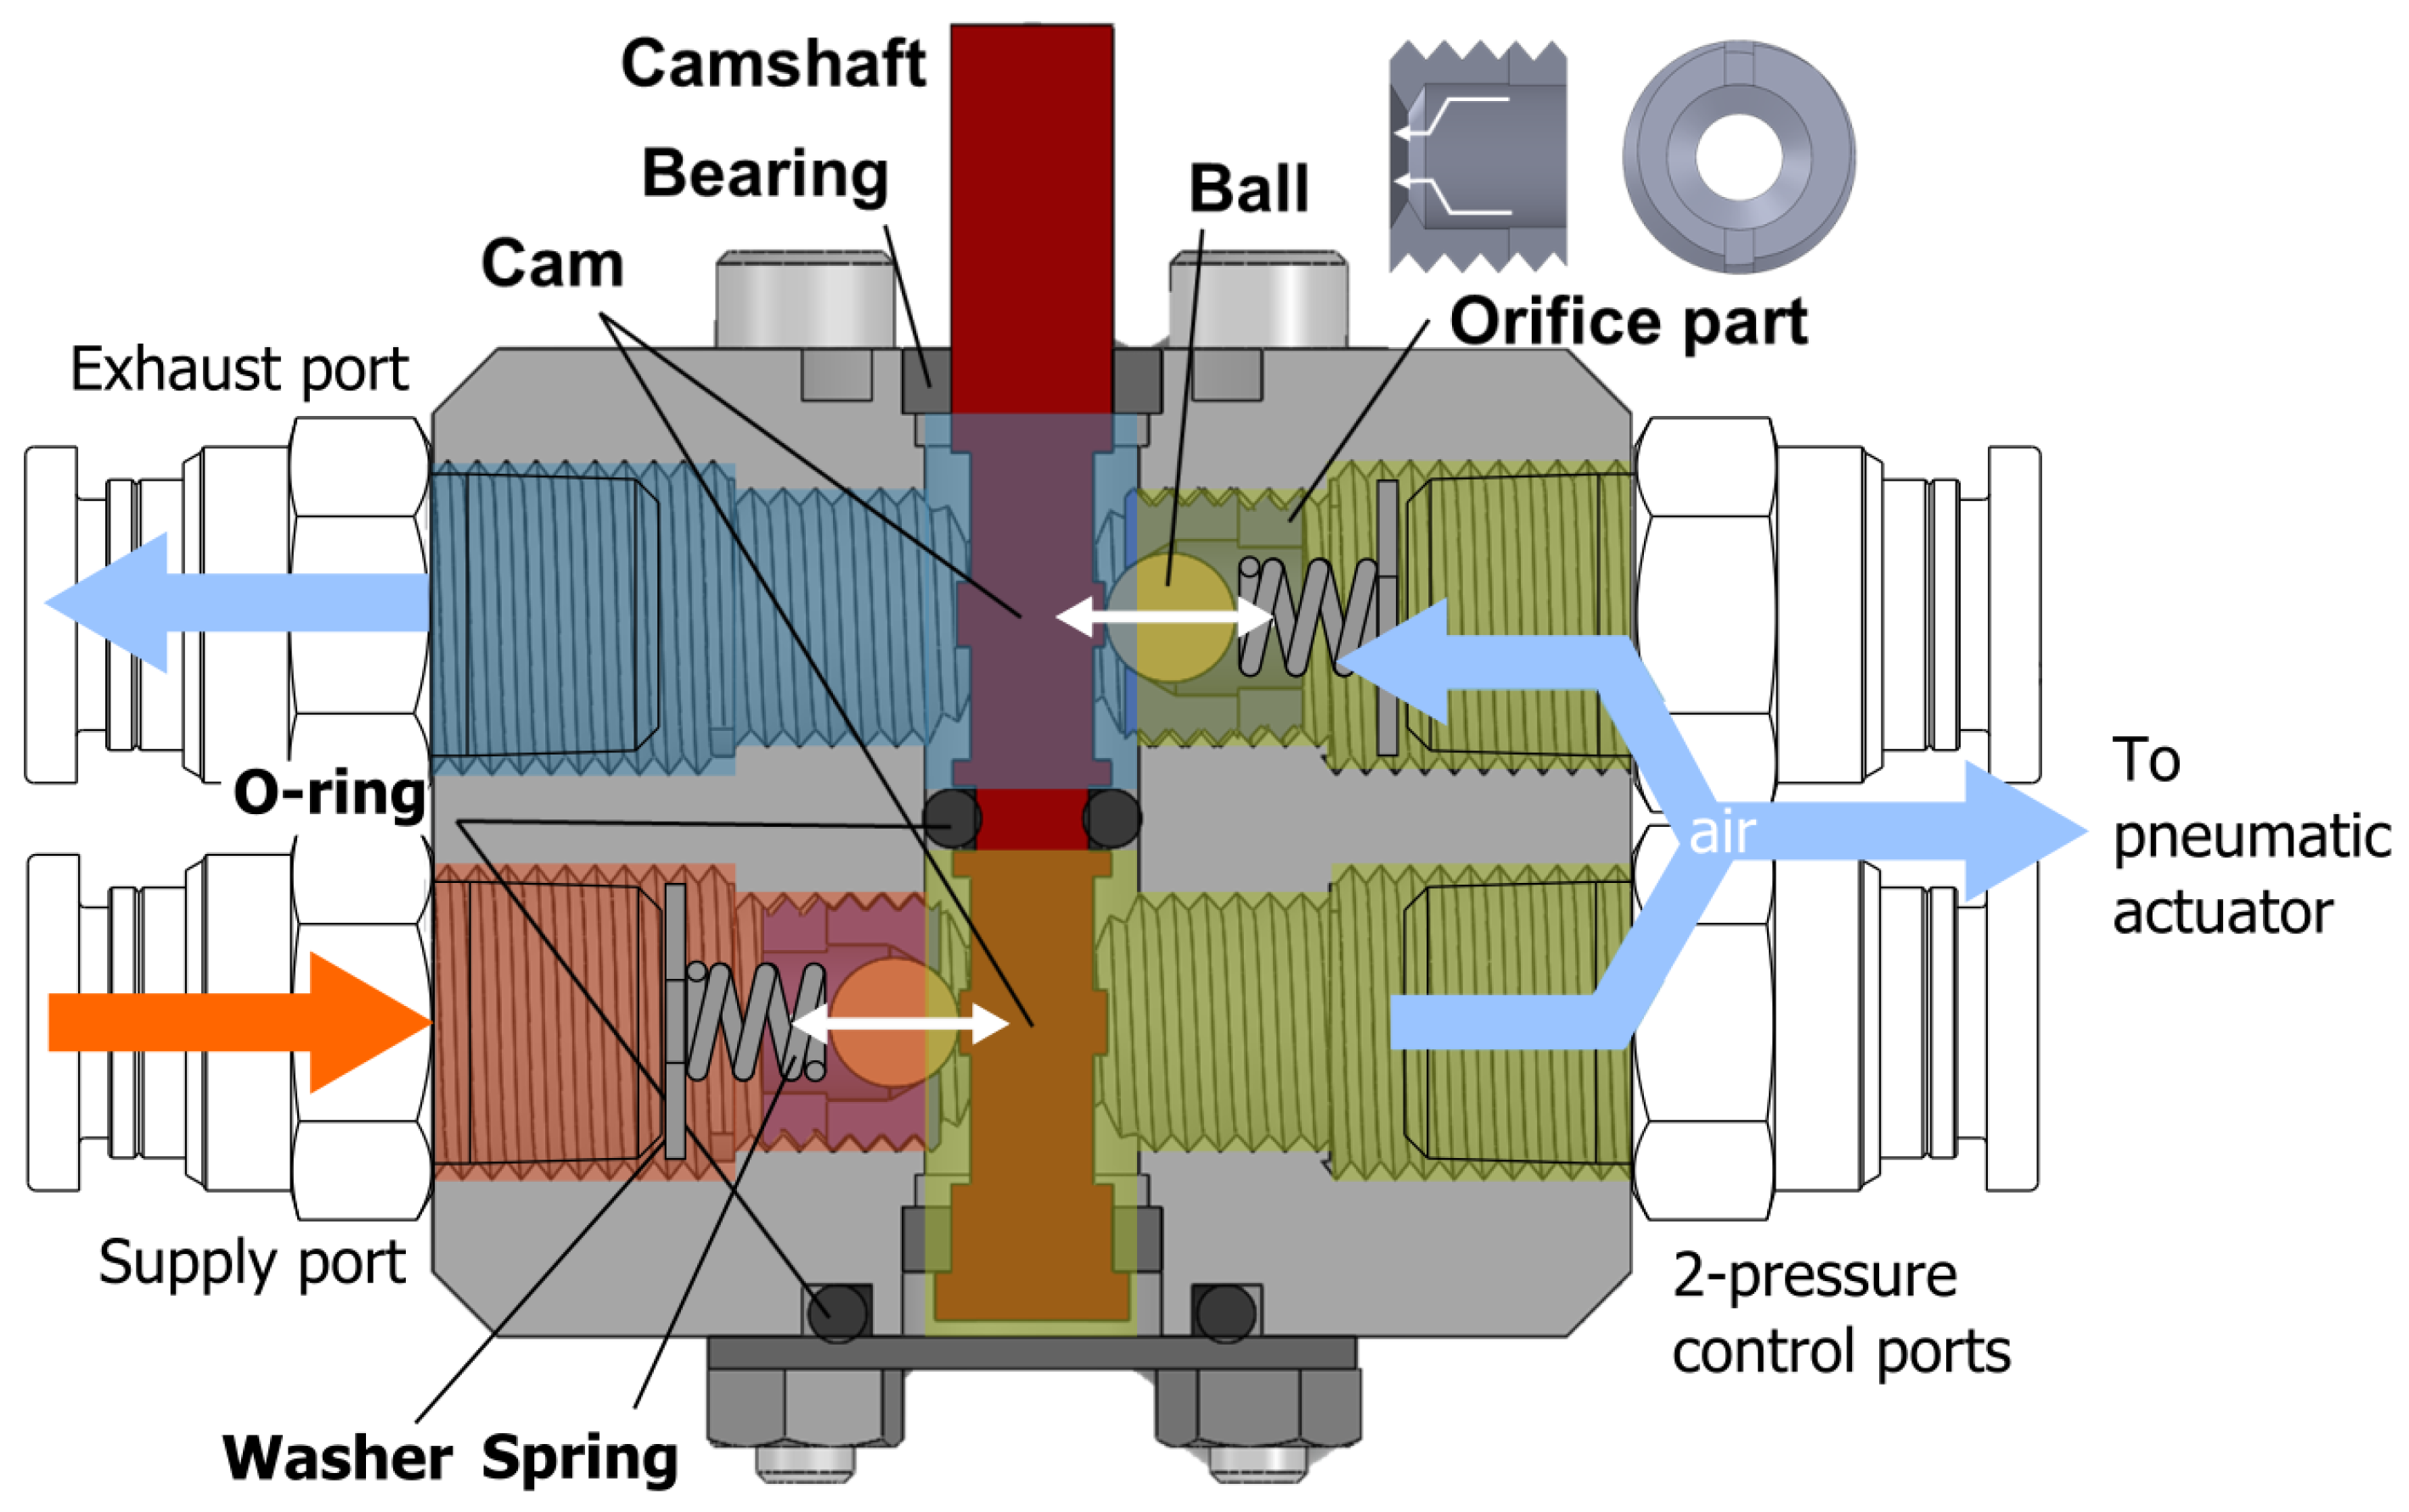
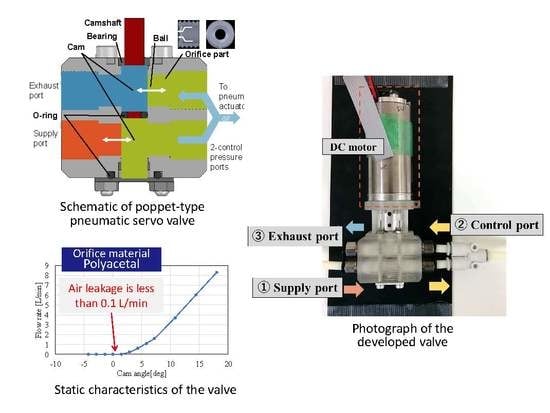
Development of a Poppet-Type Pneumatic Servo Valve

 ,
Abstract
Share and Cite
Kanno, T.; Hasegawa, T.; Miyazaki, T.; Yamamoto, N.; Haraguchi, D.; Kawashima, K. Development of a Poppet-Type Pneumatic Servo Valve. Appl. Sci. 2018, 8, 2094. https://doi.org/10.3390/app8112094
Kanno T, Hasegawa T, Miyazaki T, Yamamoto N, Haraguchi D, Kawashima K. Development of a Poppet-Type Pneumatic Servo Valve. Applied Sciences. 2018; 8(11):2094. https://doi.org/10.3390/app8112094
Chicago/Turabian StyleKanno, Takahiro, Takashi Hasegawa, Tetsuro Miyazaki, Nobuyuki Yamamoto, Daisuke Haraguchi, and Kenji Kawashima. 2018. "Development of a Poppet-Type Pneumatic Servo Valve" Applied Sciences 8, no. 11: 2094. https://doi.org/10.3390/app8112094
APA StyleKanno, T., Hasegawa, T., Miyazaki, T., Yamamoto, N., Haraguchi, D., & Kawashima, K. (2018). Development of a Poppet-Type Pneumatic Servo Valve. Applied Sciences, 8(11), 2094. https://doi.org/10.3390/app8112094