Article

Steady-State Disturbance-Rejection Controllability for LTI Systems with Rigid-Body Mode

1
Department of Mechanical and Automotive Engineering, Kongju National University, Cheonan 31080, Republic of Korea
2
Department of Mechatronics Engineering, Chungnam National University, Daejeon 34134, Republic of Korea
*
Author to whom correspondence should be addressed.
Actuators 2025, 14(12), 589; https://doi.org/10.3390/act14120589
Submission received: 26 September 2025 / Revised: 7 November 2025 / Accepted: 11 November 2025 / Published: 3 December 2025

Abstract

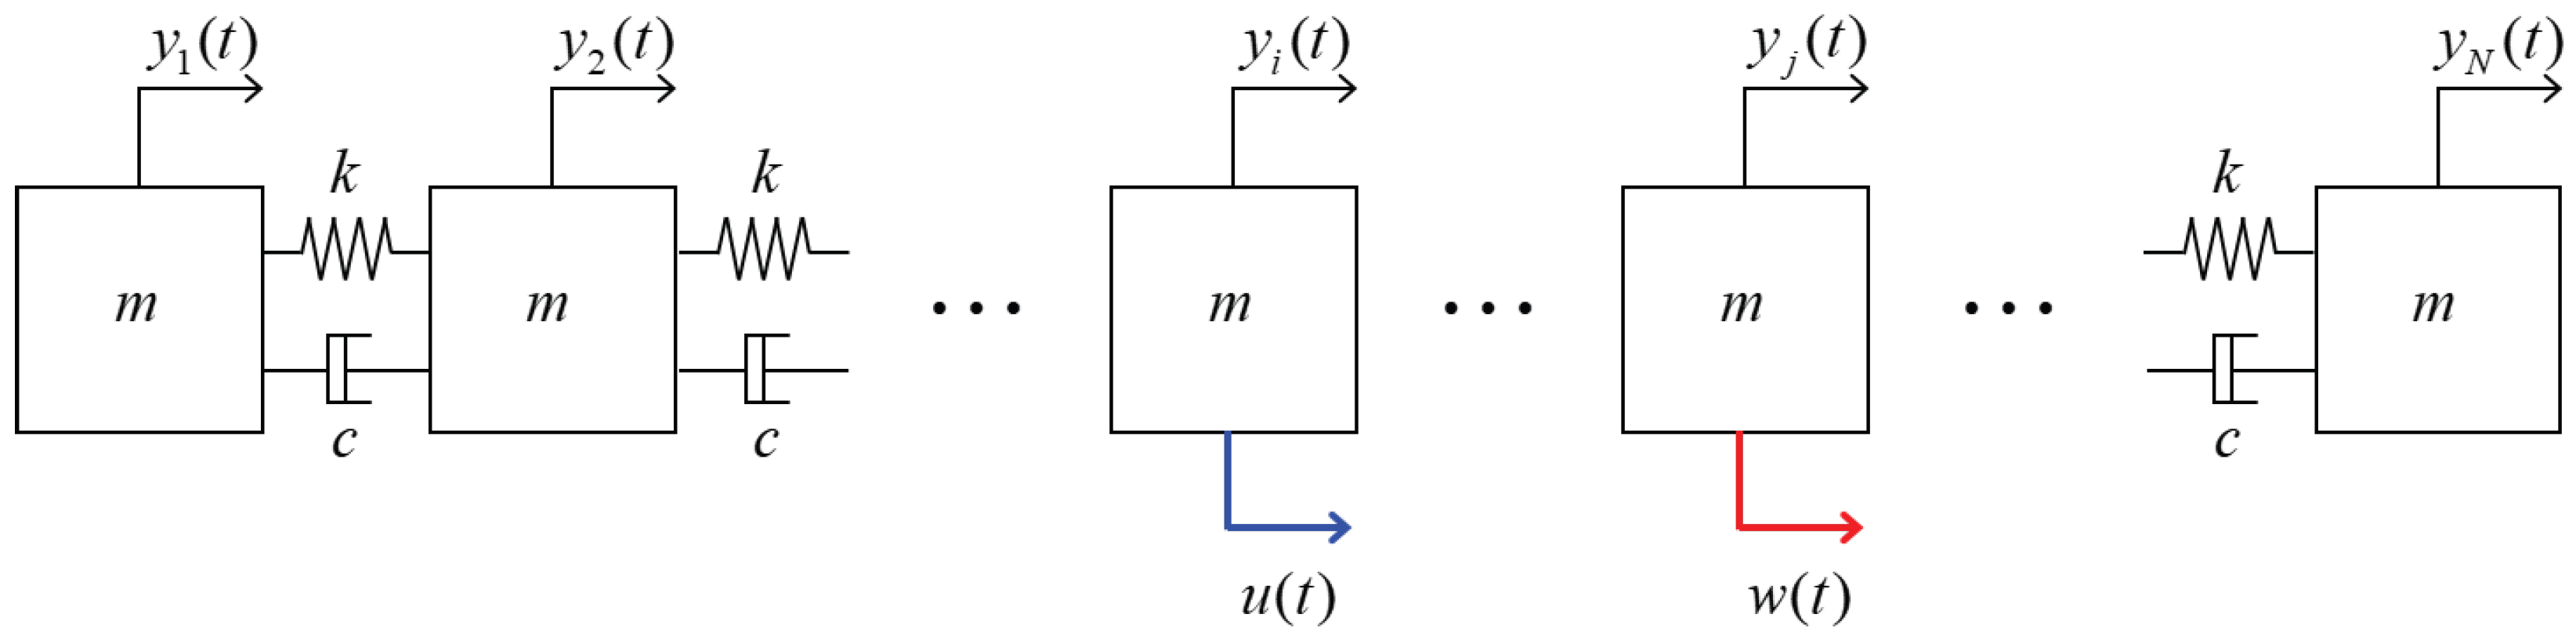
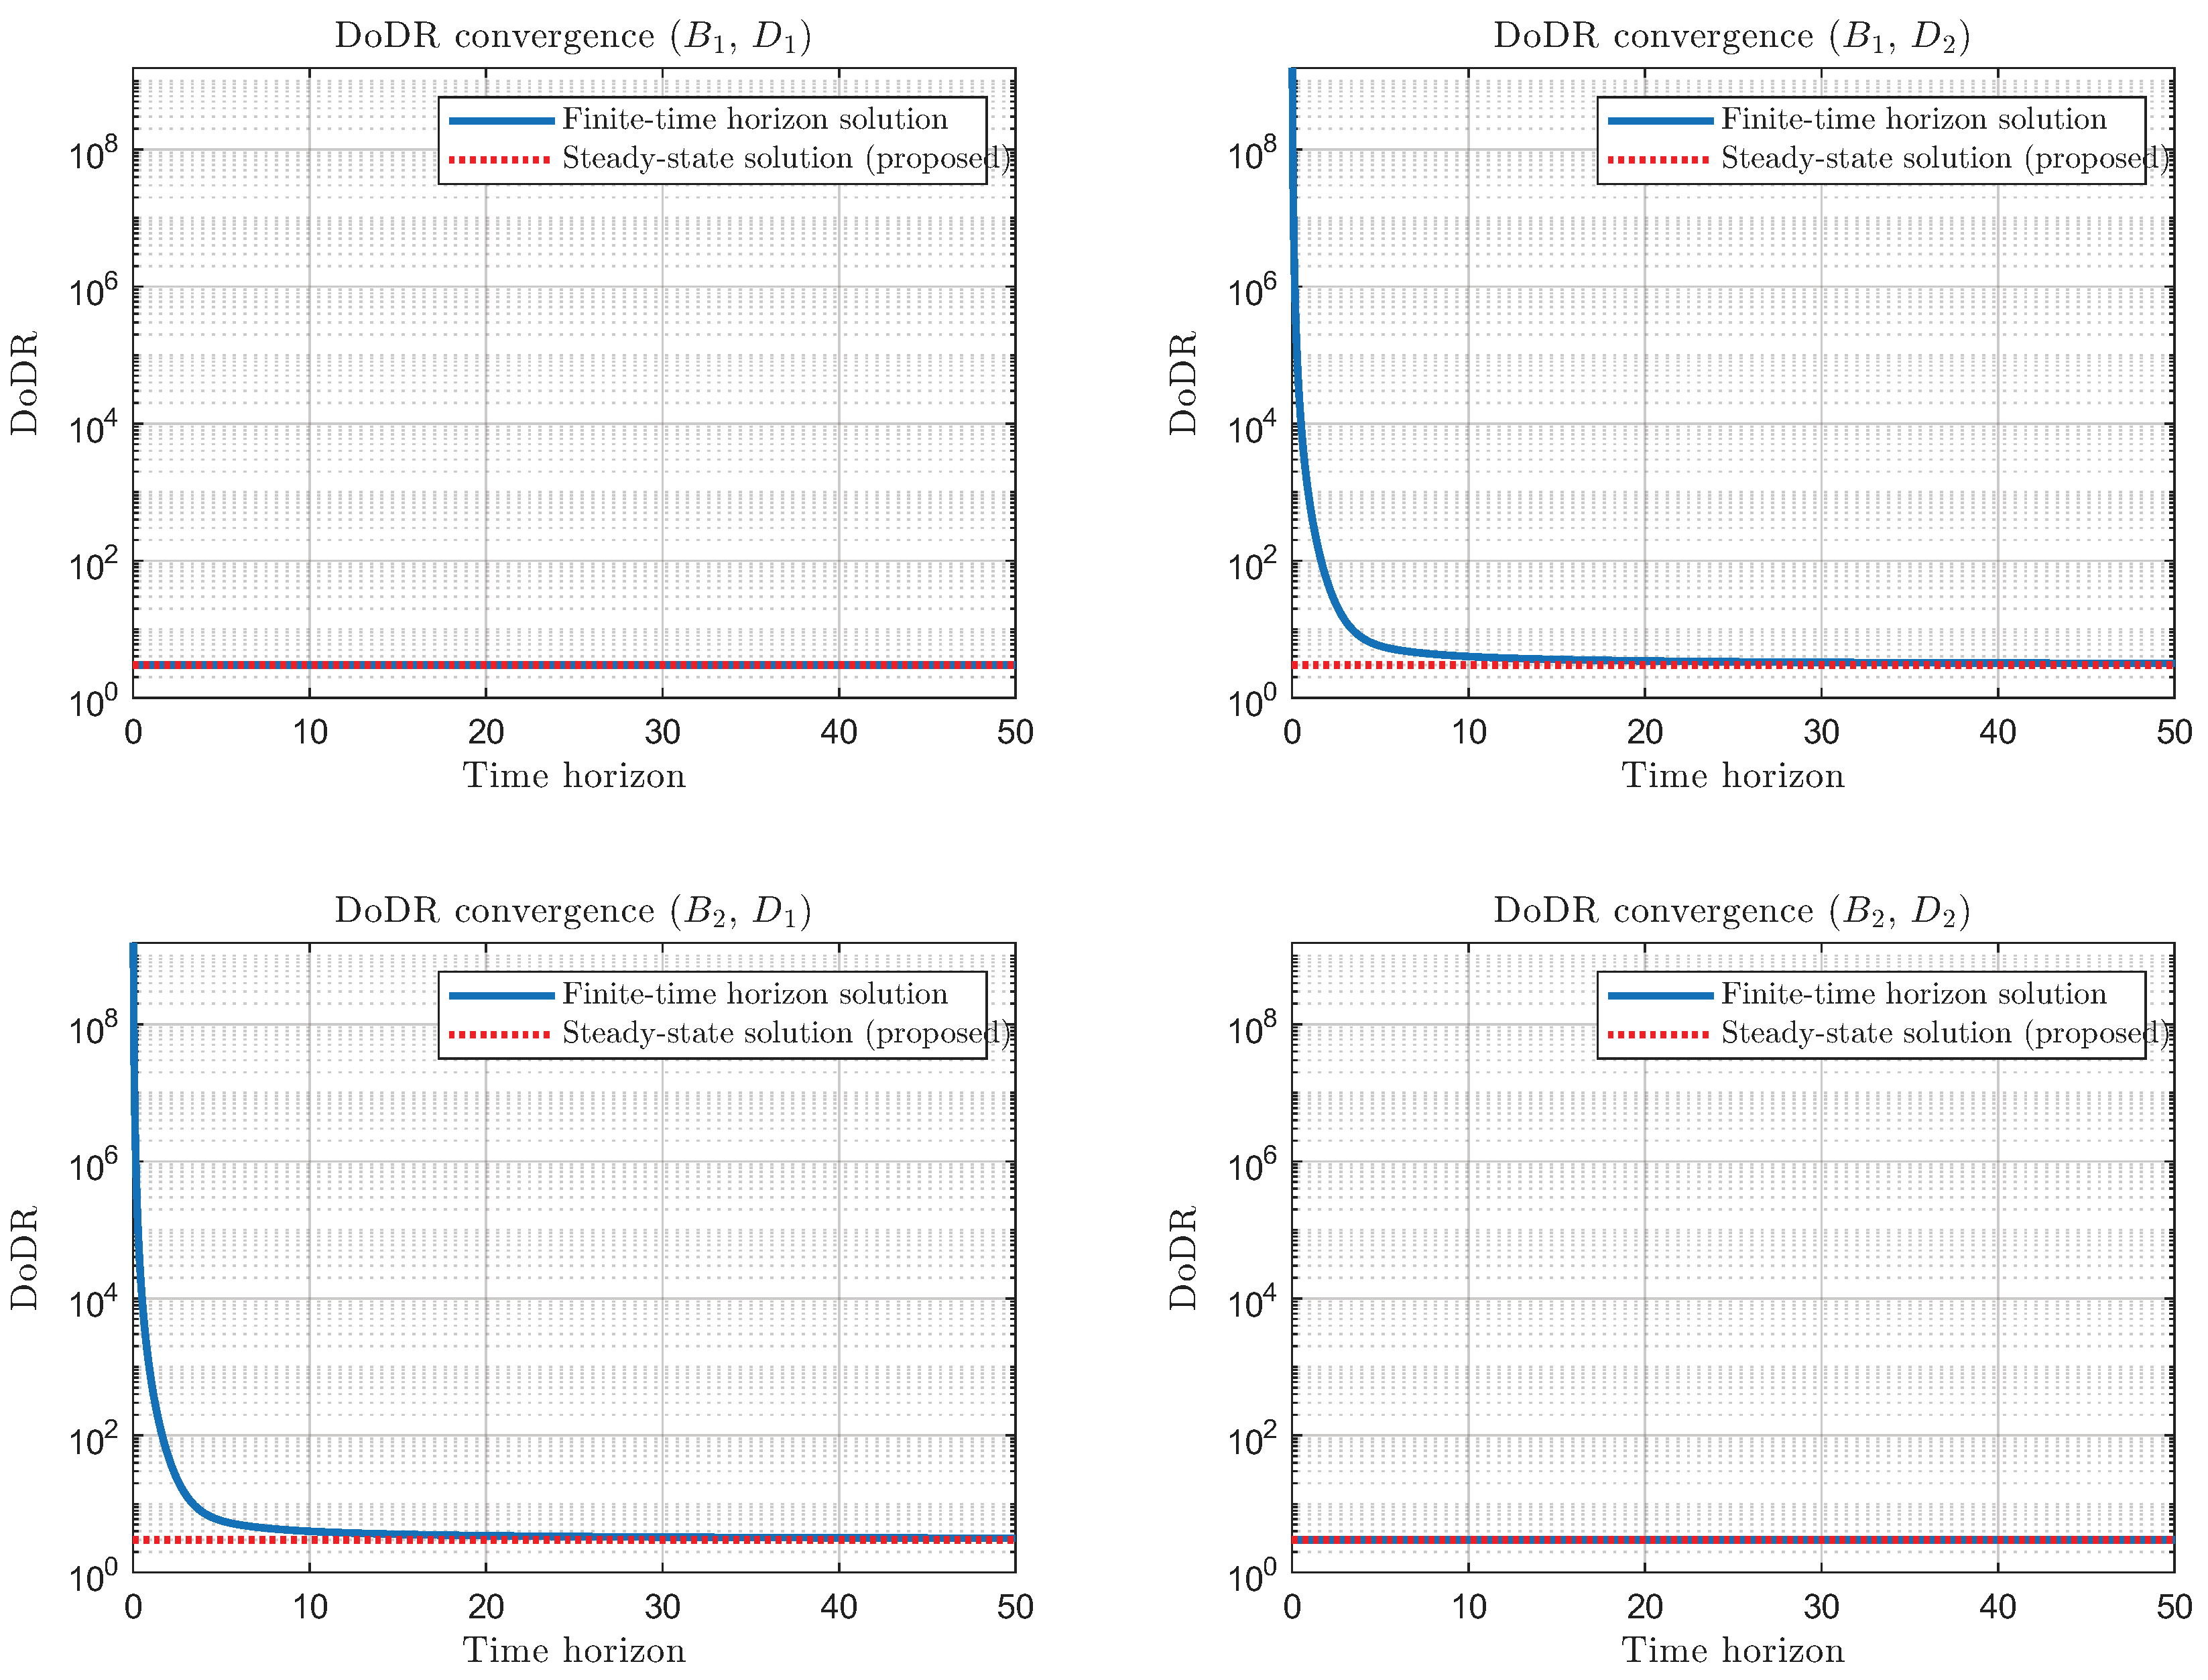
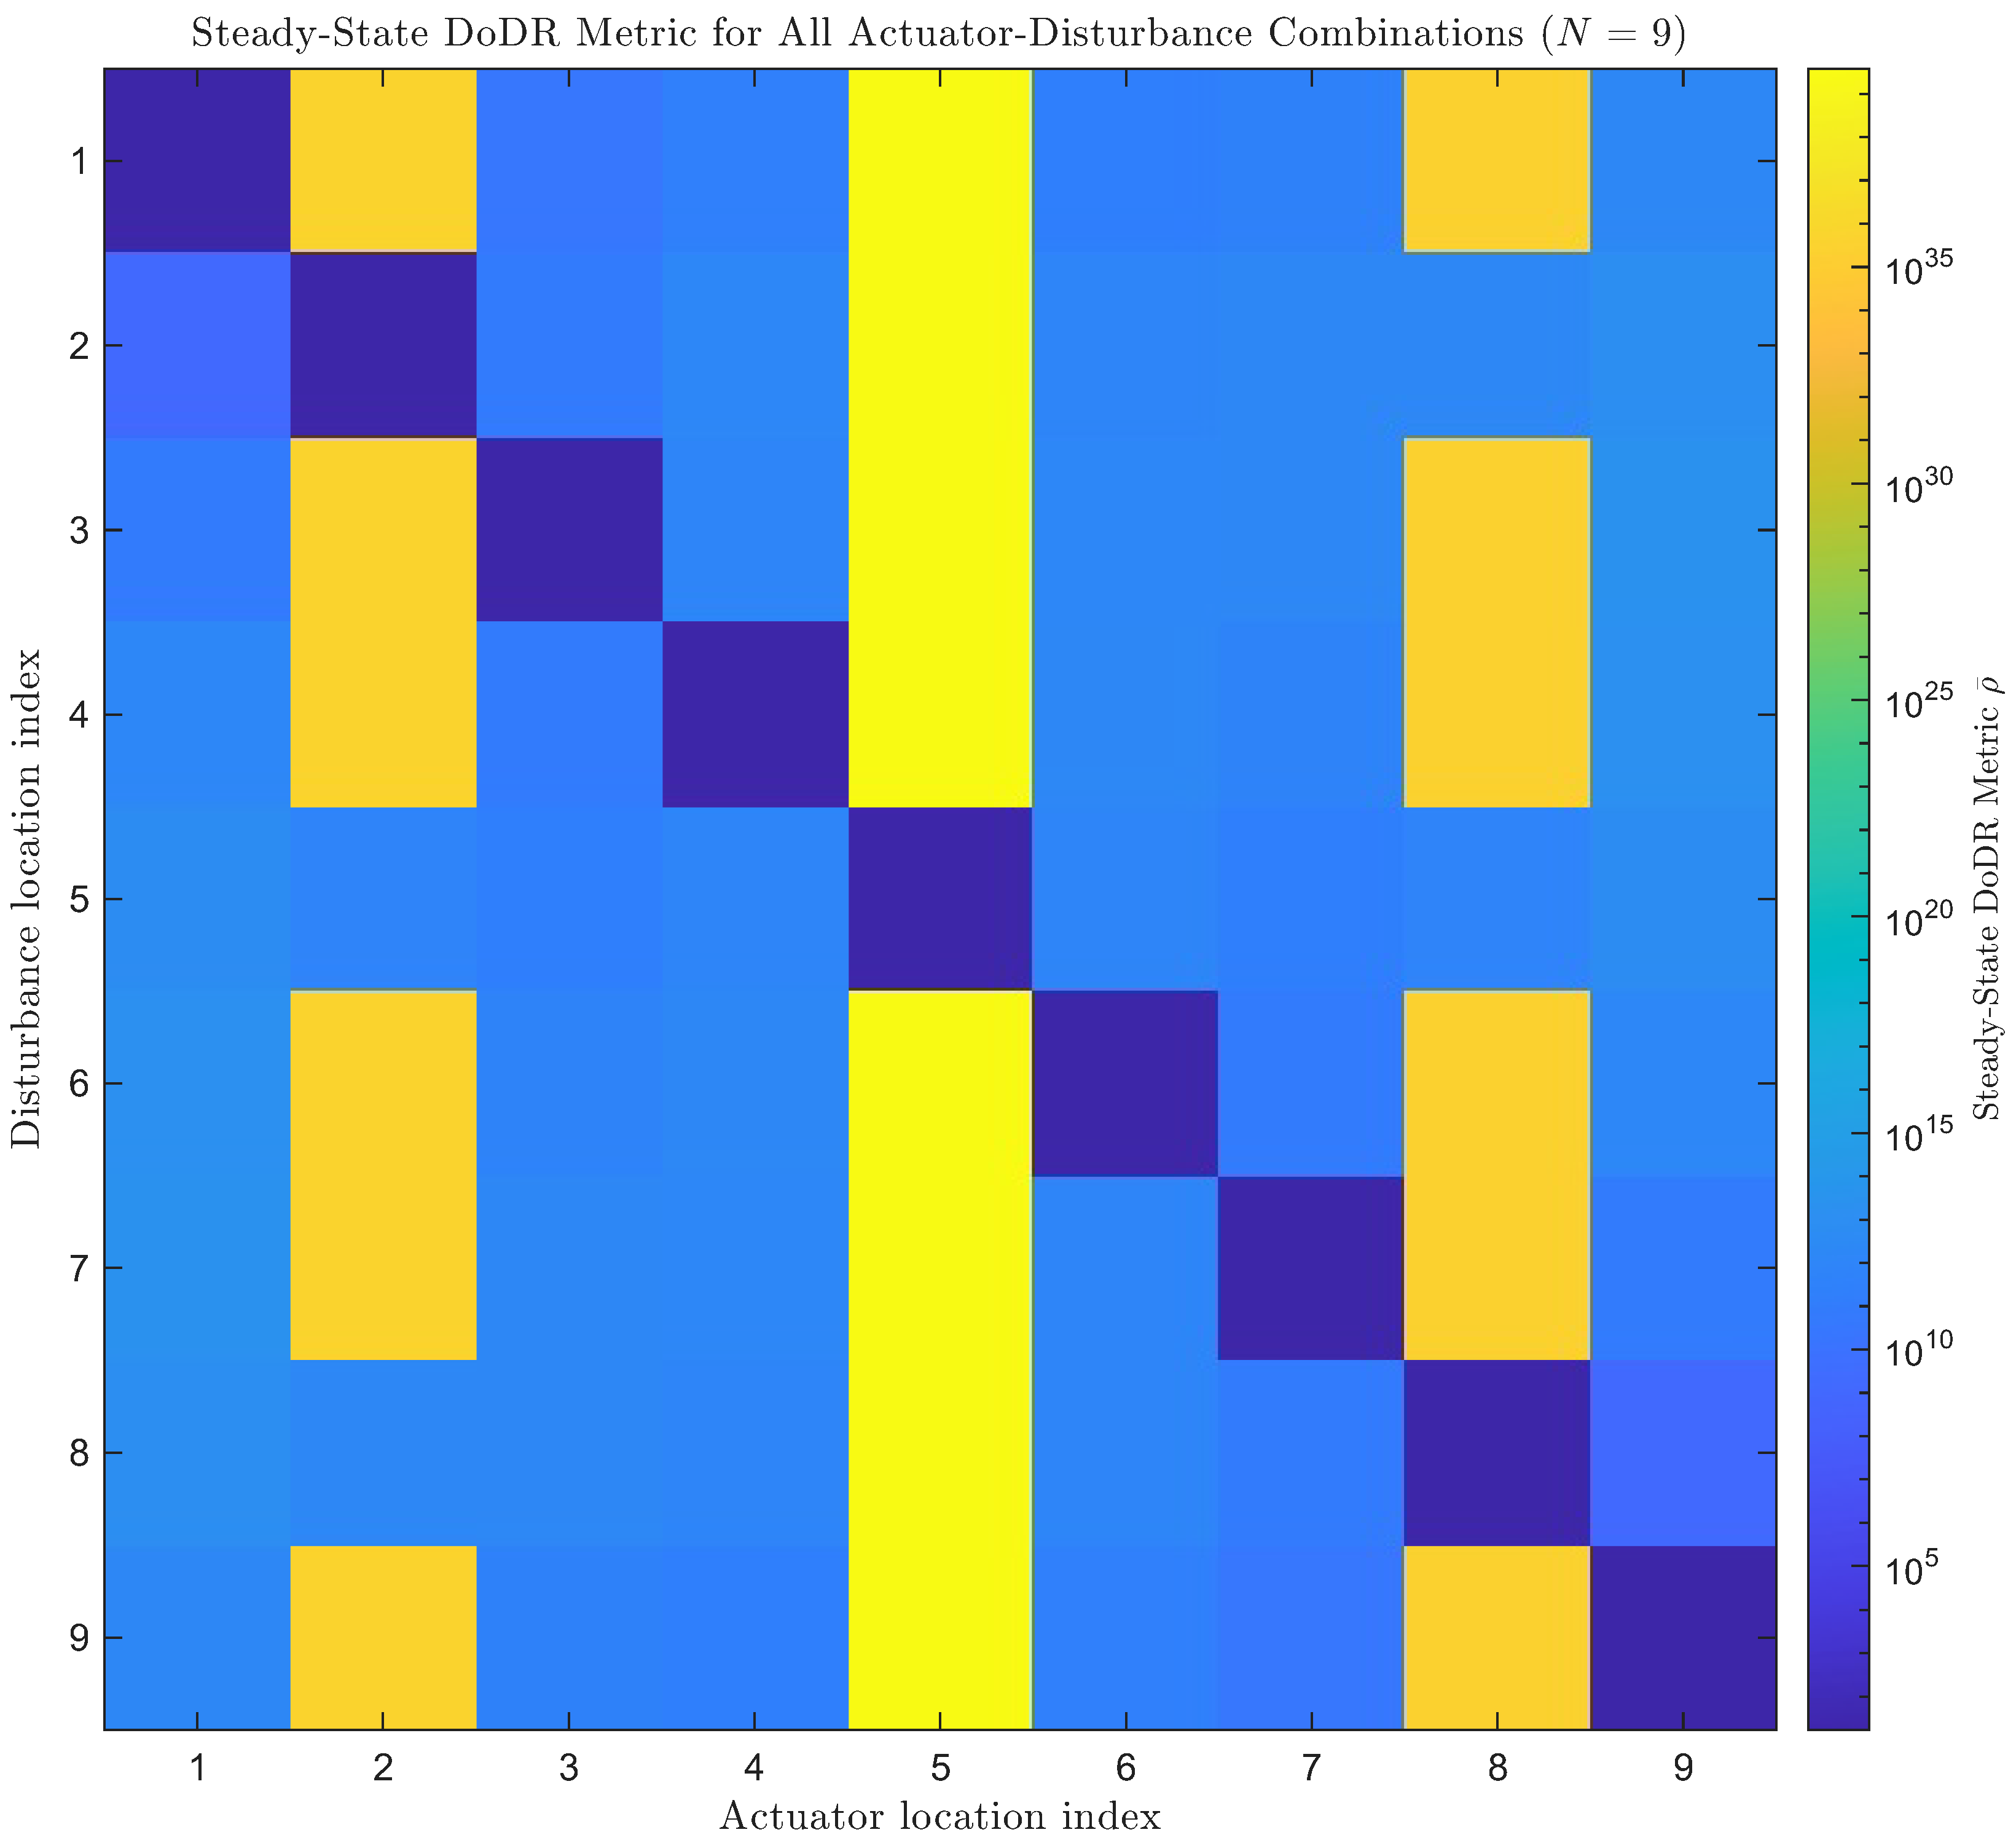
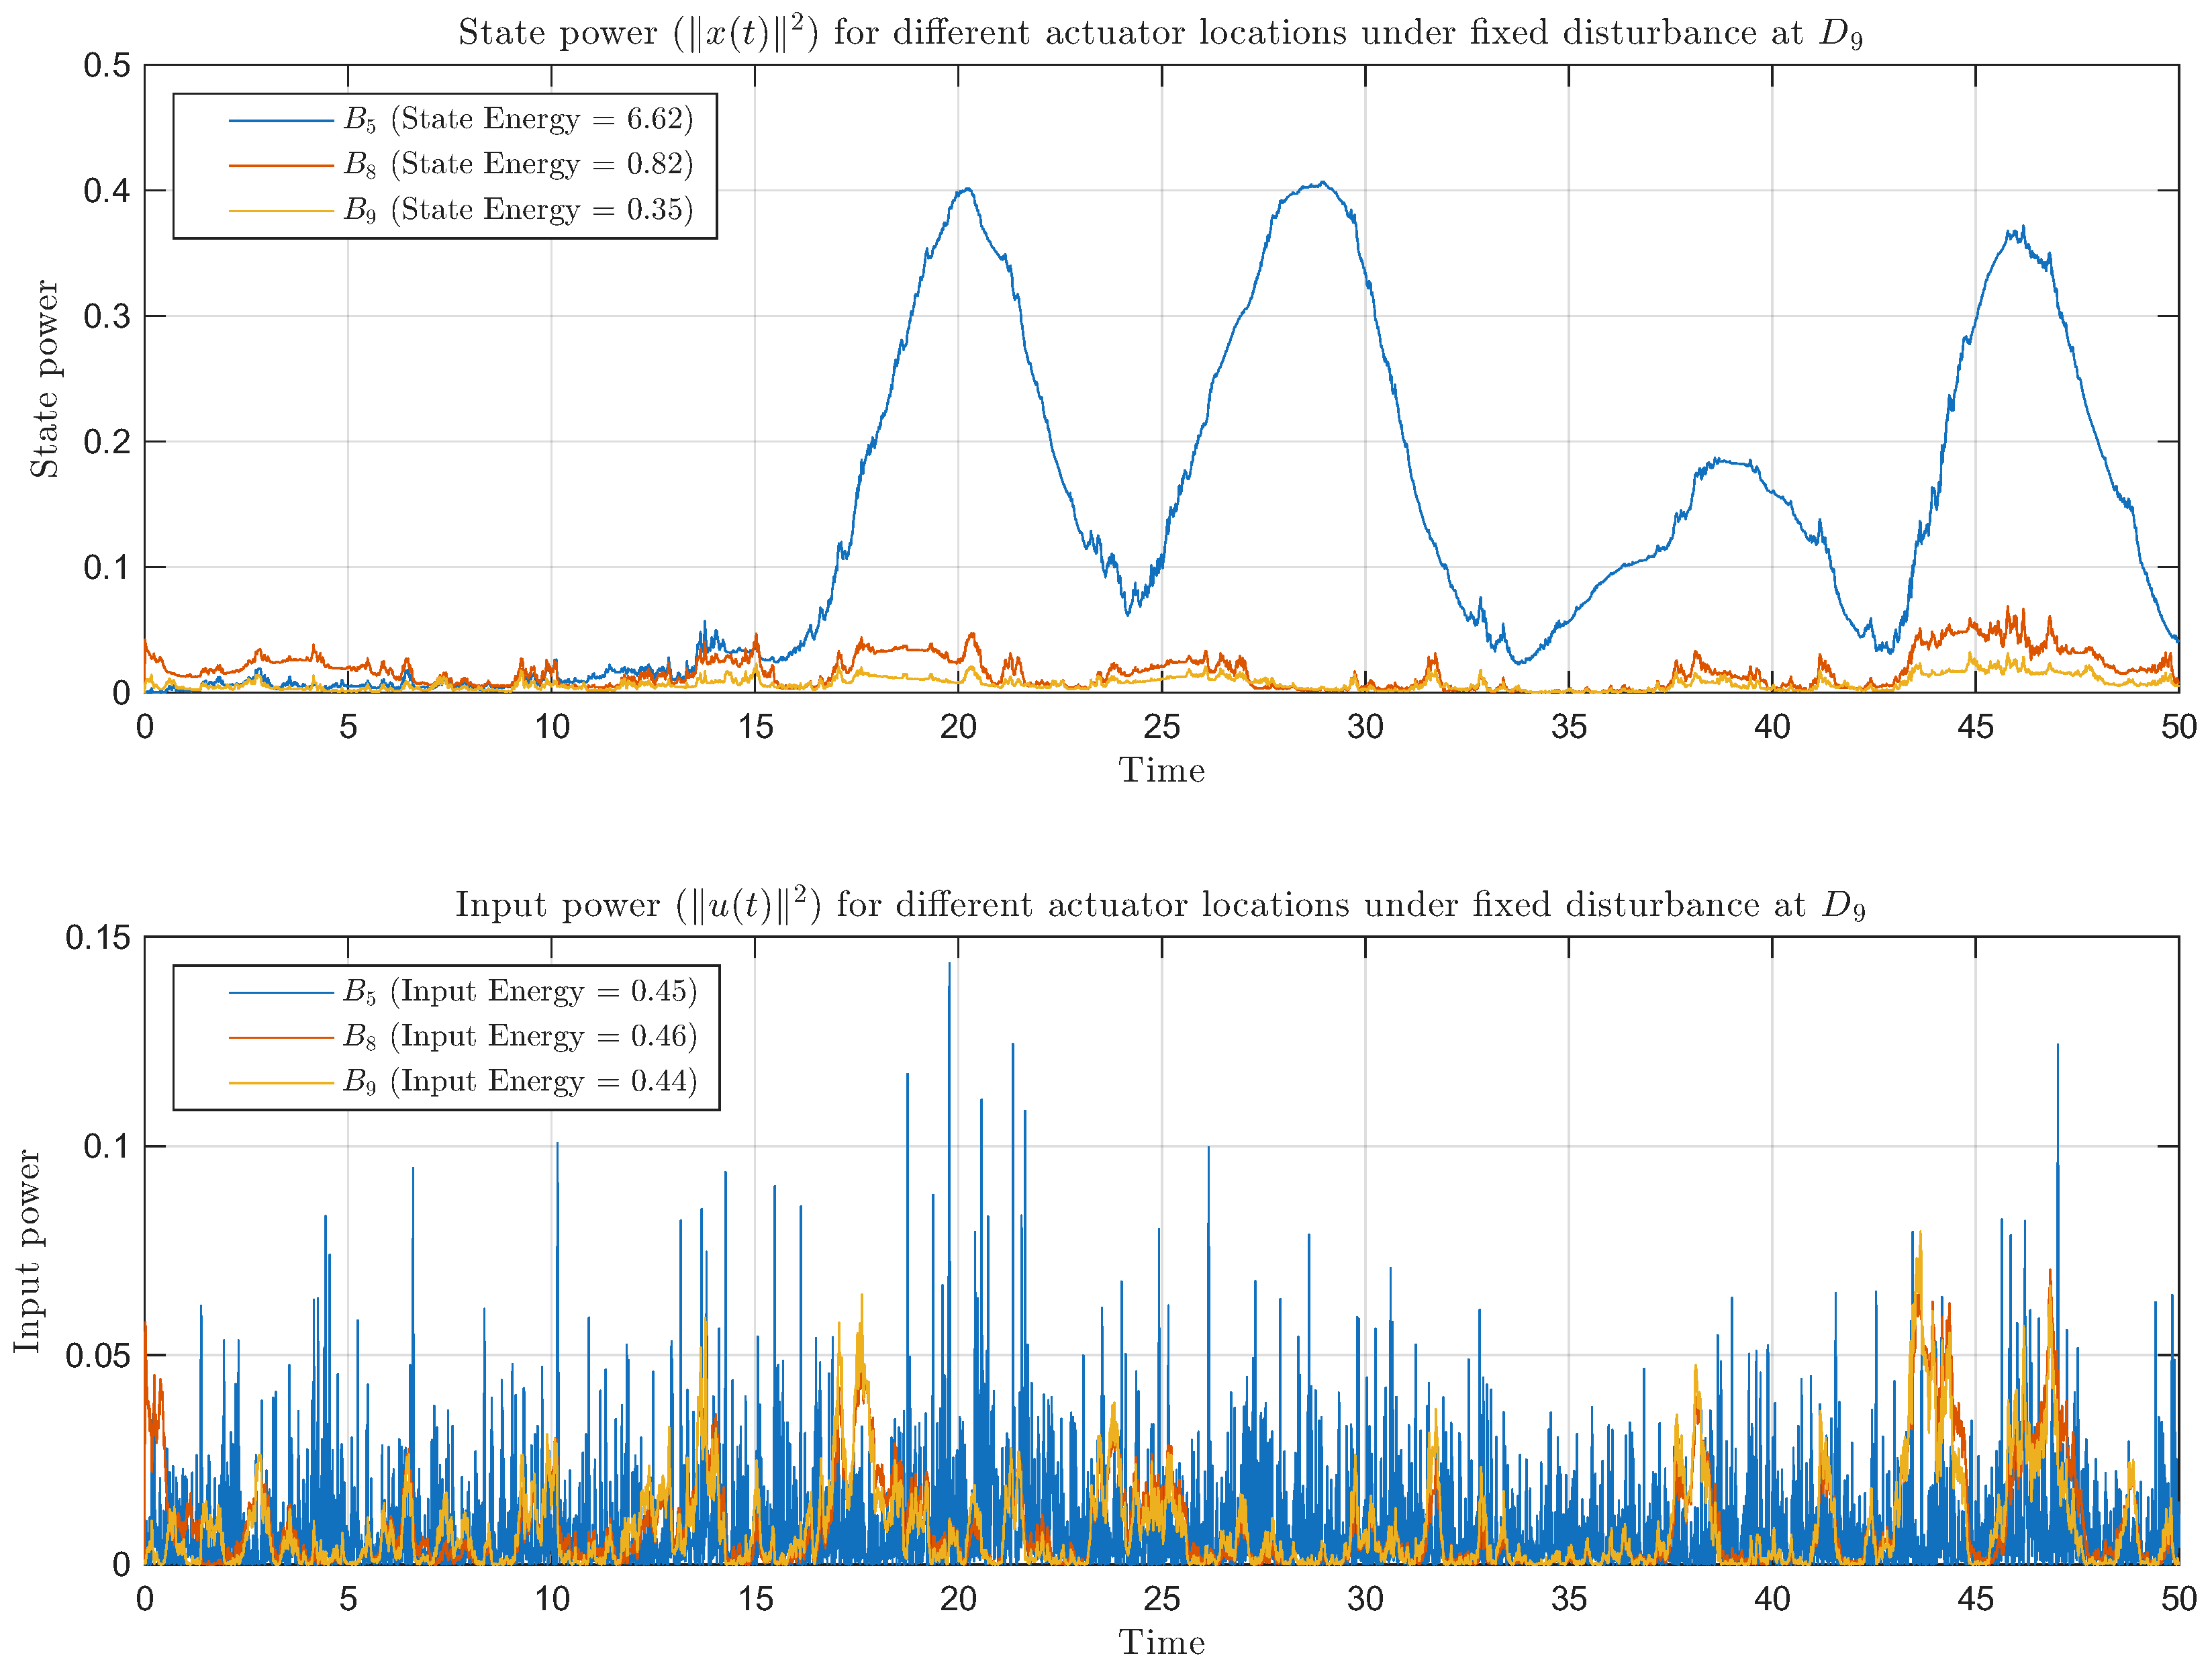
Controllability metrics based on system Gramians have been widely adopted to provide quantitative measures of the degree of controllability (DoC) and the disturbance rejection capability (DoDR) of dynamical systems. While steady-state Gramian formulations offer closed-form tractability, they are not applicable when rigid-body modes are present, as the associated poles at the origin cause the conventional Gramians to diverge. This paper presents a novel steady-state DoDR metric for linear time-invariant systems with a rigid-body mode. By block-diagonalizing the dynamics through a similarity transformation and analyzing the asymptotic behavior of the Gramian matrices, we derive an exact closed-form expression for the steady-state DoDR. The resulting formulation is numerically stable and enables systematic evaluation of disturbance-rejection capability even in the presence of a rigid-body mode. The proposed metric is validated using a mass–spring–damper chain model, where its effectiveness is demonstrated in actuator placement problems. The results show that the metric not only remains computationally well-posed but also provides physically meaningful interpretations consistent with modal characteristics. This study establishes a foundation for extending disturbance-rejection metrics to systems with multiple rigid-body modes, thereby broadening the applicability of Gramian-based controllability analysis.
Keywords: degree of controllability (DoC); degree of disturbance rejection (DoDR); rigid-body mode; steady-state solution; Gramian matrices; actuator placement degree of controllability (DoC); degree of disturbance rejection (DoDR); rigid-body mode; steady-state solution; Gramian matrices; actuator placement