


Abstract
We construct and analyze a family of support-defined Brauer-type configurations canonically associated with the Boolean geometry underlying the Grassmann algebra. The construction is governed by an x-support map on monomial labels, which identifies the vertex set with the Boolean lattice . This identification yields a Boolean support quiver isomorphic to the directed Hasse diagram of , equivalently, to an oriented hypercube. We then equip the family with a canonical cyclic ordering at each vertex and obtain a genuine connected reduced Brauer configuration in the standard sense, together with its associated Brauer configuration algebra and its standard Brauer quiver. A ghost-variable mechanism is introduced to obtain a connected realization without altering any support-controlled invariants. We prove that polygon membership, valencies, multiplicities, Boolean stratification, and the support quiver are invariant under support-preserving ghost relabelings. We also give an explicit description of the standard Brauer quiver and show that it is different from the Boolean support quiver. On the algebraic side, we derive closed formulas for the center dimension, the algebra dimension, and the normalization constant of the induced weighted distribution. On the probabilistic side, we distinguish the vertex entropy from the layer entropy, establish an exact decomposition of the former by Hamming layers, and show that the layer distribution is asymptotically concentrated on the middle layers, while extremal vertices and any fixed maximal path contribute a negligible fraction of the total weight. As a consequence, the layer entropy satisfies a logarithmic asymptotic law. We also investigate geometric consequences of the Boolean model transported through the support identification. Coordinate projections produce a rigidity phenomenon for antipodal pairs, providing a combinatorial analogue of Greenberger–Horne–Zeilinger (GHZ)-type fragility, whereas the first Boolean layer exhibits a persistence property analogous to W-type robustness. Together, these results exhibit a concrete bridge between Grassmann combinatorics, Brauer configuration theory, hypercube geometry, and entropy asymptotics.
Keywords:
Brauer configuration algebra; Brauer configuration; Brauer data analysis; covering graph; Grassmann algebra MSC:
16G20; 05E18; 05C90; 15A75; 81P40
1. Introduction
The Grassmann (or exterior) algebra occupies a distinguished place in algebra, geometry, and mathematical physics because it provides one of the most elementary settings in which anticommutativity, grading, and combinatorics interact in a genuinely structural way. Let V be an n-dimensional vector space over a field K, and let
denote its exterior algebra. After fixing a basis of V and writing for the image of in , one obtains the familiar relations
which make the universal algebra governing alternating multilinear phenomena. For this reason, exterior algebras permeate the study of determinants, orientations, differential forms, cohomology, and fermionic sign rules; see, for instance, refs. [1,2,3].
A first guiding principle of the present work is that the Grassmann algebra should not be viewed only as a receptacle for alternating tensors, but also as a canonically graded and combinatorially indexed object. On the one hand, is naturally a -graded algebra,
and homogeneous elements satisfy the super-commutation rule
This superalgebra viewpoint is foundational in the theory of Lie superalgebras and in supersymmetry; see [4,5]. On the other hand, recent work shows that even the collection of superalgebra structures carried by the Grassmann algebra is itself a subtle invariant, governed by involutive automorphisms and graded identities [6]. This perspective is relevant for us because it suggests that the Grassmann algebra carries not only algebraic structure in the usual sense, but also an internal combinatorial architecture rich enough to support additional representation-theoretic models.
A second guiding principle is that the canonical monomial basis of the Grassmann algebra is indexed by the Boolean lattice. Every basis monomial
corresponds uniquely to the subset
Thus, the natural monomial basis of is indexed by , and the homogeneous component of degree k has dimension . In other words, the basis combinatorics of the Grassmann algebra is exactly the combinatorics of the n-dimensional hypercube . This observation is elementary, but it is also remarkably fertile: it imports into the study of the order structure of the Boolean lattice, the geometry of Hamming layers, and the concentration phenomena encoded by binomial coefficients; see [7,8,9]. From a graph-theoretic viewpoint, the hypercube is one of the basic examples of a distance-regular graph, and its algebraic structure has been studied from several complementary directions [10,11].
This Boolean indexing becomes particularly suggestive when viewed through the lens of quantum information. The Hilbert space of n qubits is , whose computational basis is again indexed by bitstrings in , hence by subsets of ; see [12]. Under this identification, the natural discrete metric is the Hamming distance
where denotes symmetric difference. This metric measures the number of local coordinate flips needed to pass from one basis state to another, and it underlies many of the discrete geometric intuitions surrounding locality and multipartite entanglement [13]. In particular, the familiar distinction between Greenberger–Horne–Zeilinger (GHZ)-type and W-type entanglement may be read combinatorially as a distinction between highly global extremal configurations and more robust low-degree layers [14,15]. One of the conceptual aims of this article is to show that this heuristic may be encoded in an explicit Brauer-type framework built from the Boolean geometry inherent in the Grassmann algebra.
The main objective of the paper is therefore to construct and analyze a family of support-defined Brauer-type configurations canonically attached to the Boolean geometry underlying the Grassmann algebra. More precisely, we build a family in which the vertices are controlled by monomial labels in commuting variables, while the incidence pattern is governed entirely by the x-support of those monomials. This support map identifies the vertex set with the Boolean lattice , and from this identification there emerges a canonical Boolean support quiver, namely the directed Hasse diagram of , or equivalently, the oriented hypercube. The first important point is that this support quiver is not yet the standard Brauer quiver of a Brauer configuration algebra. Rather, it is the combinatorial shadow of the support geometry. A separate step is needed in order to endow the family with a genuine Brauer configuration structure in the standard sense.
This distinction is one of the main structural clarifications of the paper. Starting from the support-defined family , we introduce a canonical cyclic ordering of the polygons incident with each vertex, thereby obtaining a connected reduced Brauer configuration
in the standard sense. This, in turn, determines a genuine Brauer configuration algebra and its associated standard Brauer quiver . The support quiver and the standard Brauer quiver are thus different but complementary objects: the first records Boolean support inclusions, while the second records successor relations among polygons induced by the cyclic orientation. One of the results of the paper is that these two quivers are not isomorphic, a fact that becomes essential in the computation of global invariants.
This strategy places the present work within the rapidly growing theory of Brauer graph algebras and Brauer configuration algebras. Brauer configuration algebras generalize the Brauer graph algebras by allowing polygons with repeated vertices and more flexible multiplicity data, while retaining a highly computable combinatorial control over the associated algebra [16,17]. Their structure has since been enriched by several complementary developments, including geometric models for Brauer graph algebras [18,19], extensions toward weighted surface algebras [20], and explicit formulas for invariants such as center dimensions [21]. In parallel, Brauer configuration techniques have been adapted to a variety of combinatorial sources, including Dyck paths, snake graphs, -configurations, integer partitions, and graph-theoretic constructions [22,23,24,25,26]. Our contribution fits naturally into this circle of ideas, but its distinctive feature is that the controlling combinatorics is neither Catalan nor partition-theoretic in the usual sense: it is the Boolean geometry already present in the Grassmann algebra itself.
The key combinatorial device in our construction is the x-support map. Working with commuting variables and a small family of auxiliary symbols, we label vertices by monomials w and set
The crucial point is that all incidence relations, as well as the valency and multiplicity functions appearing in the configuration, depend only on and on its cardinality. Thus, the algebraic data is funneled rigidly through the Boolean lattice . This support-level description is strong enough to recover the Boolean stratification by Hamming layers, the oriented Hasse diagram, and the recursive doubling behavior in the parameter n.
One of the delicate technical issues is connectedness. In Brauer-configuration theory, connectedness is not a superficial graph-theoretic convenience, but a structural requirement ensuring that the associated algebra reflects the intended global geometry rather than decomposing into unrelated pieces. For this reason, the paper incorporates a ghost-variable principle: we enlarge the ambient monomial system by adjoining a finite collection of auxiliary variables that do not contribute to . As a result, the Boolean support geometry remains unchanged, while the configuration admits a connected realization compatible with the Brauer framework. In particular, the quantities that govern the theory, such as polygon membership, multiplicity and valency counts, Boolean stratification, support quiver structure, and the global sums derived later, remain entirely controlled by the x-support. This separation between support data and auxiliary presentation is one of the conceptual novelties of the paper.
A second major theme of the article is quantitative. Because multiplicities and valencies depend only on the size of the x-support, the principal global sums reduce to binomial expressions over Hamming layers. This allows us to derive explicit formulas for the dimension of the center, the total dimension of the Brauer configuration algebra, and the normalization constant of the weighted distribution induced by multiplicity and valency. One noteworthy consequence of the corrected Brauer-quiver analysis is the formula
The weighted distribution also gives rise to two distinct entropy-type quantities: a vertex entropy, defined on the full vertex set, and a layer entropy, defined on the induced distribution over Hamming layers. A key point, emphasized in the present version of the paper, is that these two quantities are not the same. The vertex entropy decomposes exactly into a layer contribution plus an internal contribution coming from the multiplicity of vertices inside each Hamming layer. The layer distribution itself is asymptotically concentrated on the middle layers, while extremal vertices and any fixed maximal path contribute only a negligible fraction of the total mass. As a consequence, the layer entropy satisfies a logarithmic asymptotic law.
A third major theme is geometric. Once the support identification
has been established, the hypercube geometry of the Boolean lattice can be transported back to the support-defined family. The resulting statements should be understood as consequences of the Boolean model carried by the support map, rather than as intrinsic properties of the standard Brauer quiver itself. From this viewpoint, coordinate projections produce a rigidity phenomenon for antipodal pairs: maximally separated pairs lose exactly one unit of Hamming distance under each coordinate deletion. At a purely combinatorial level, this mirrors the fragility usually associated with GHZ-type configurations. At the opposite end of the Boolean lattice, the first Hamming layer behaves in a markedly different way: under deletion of any single coordinate, a nontrivial portion of that layer survives through a canonical order-preserving identification with the first layer of . This persistence provides a combinatorial analogue of W-type robustness. In this way, the Boolean support model captures within a single framework both the fragility of global extremal structures and the persistence of low-degree strata.
Another feature of the family is its clean inductive behavior in the parameter n. Passing from to n amounts to adjoining one new coordinate, hence doubling the Boolean lattice into two copies according to whether the new index n is absent or present. On the level of vertex labels, this operation is realized by the lift map
which identifies the second layer with the labels whose support contains n. This recursive structure is important both conceptually and technically. Conceptually, it shows that the family is not sporadic but hierarchical. Technically, it allows one to propagate support data, valencies, and layer counts across consecutive values of n, in a spirit familiar from other Brauer-configuration families built from combinatorial recursion [24,25].
Taken together, these ideas lead to a threefold synthesis that we regard as the main conceptual contribution of the paper. On the algebraic side, the Grassmann algebra contributes the canonical superalgebra structure and the Boolean indexing of basis monomials [2,3,6]. On the Brauer-theoretic side, standard Brauer configuration theory furnishes a flexible finite-dimensional framework in which this Boolean geometry becomes visible through an explicitly connected reduced Brauer configuration and a computable associated algebra [16,17,21]. On the combinatorial-geometric side, the support identification makes Hamming distance, coordinate projection, antipodal rigidity, W-type persistence, and middle-layer concentration part of a single coherent picture [8,12,13,14,15]. The ghost-variable mechanism ensures that this synthesis is not derailed by connectivity issues, because it provides a connected realization without contaminating the invariant support core.
We close this introduction by indicating the organization of the paper. We begin by defining the monomial system and the x-support map that transfers the Boolean structure of the Grassmann algebra into the language of support-defined Brauer-type configurations. We then construct the vertex and polygon families, prove that the vertex set is canonically identified with the Boolean lattice, and introduce the Boolean support quiver as the directed Hasse diagram of that lattice. After that, we equip the family with a canonical cyclic ordering, obtain a genuine connected reduced Brauer configuration in the standard sense, and describe explicitly the associated standard Brauer quiver. We next establish connectedness, reducedness, ghost invariance, and the inductive lift structure, and then derive formulas for the center dimension, the algebra dimension, and the weighted distributions governing the entropy theory. Finally, we turn to the geometric consequences transported from the Boolean lattice, including the rigidity of antipodal pairs under coordinate projections, the contrast with the persistence of the first Boolean layer, and several open problems suggested by this Brauer-theoretic Boolean model. In this way, the article develops a framework in which the Boolean skeleton of the Grassmann algebra is not only visible, but mathematically operative.
For reference, Appendix A contains low-dimensional realizations of the vertex sets , including explicit diagrams for the cases , , and , together with a complete worked example for .
Main Results
We briefly summarize the principal constructions and results established in this paper.
Our starting point is the observation that the Boolean geometry naturally underlying the Grassmann algebra can be transferred into a Brauer-type framework through the x-support map. More precisely, after defining a suitable family of monomial labels and an incidence structure governed entirely by x-supports, we construct for each a support-defined family whose vertex set is canonically identified with the Boolean lattice via the support map (Proposition 2). Under this identification, the associated Boolean support quiver is shown to be exactly the directed Hasse diagram of the Boolean lattice, equivalently, the oriented n-dimensional hypercube (Proposition 3).
A second main result is that this support-defined family can be completed into a genuine Brauer configuration in the standard sense. By introducing a canonical cyclic ordering on the polygons incident with each vertex, we obtain a connected reduced Brauer configuration and hence a well-defined Brauer configuration algebra (Theorem 1). We then define and compute explicitly the associated standard Brauer quiver (Theorem 2), and we show that it is not isomorphic to the Boolean support quiver (Corollary 1). This distinction is one of the structural points on which the present version of the paper rests.
A third group of results concerns the structural properties of the family. We prove that the incidence graph of is connected (Theorem 3), that the family has no truncated vertices and is therefore reduced (Proposition 7), and that the Boolean support quiver is loop-free (Proposition 8). At the same time, we show that the auxiliary ghost variables used in the construction do not alter any of the support-controlled data: polygon membership, valency, multiplicity, Boolean stratification, and the support quiver all remain invariant under support-preserving ghost relabelings (Proposition 6). In this sense, the ghost mechanism provides a connected realization without contaminating the invariant Boolean core of the theory.
The fourth group of results is quantitative. Because multiplicities and valencies depend only on the size of the x-support, all global sums reduce to binomial expressions over Hamming layers. This allows us to derive explicit closed formulas for the center dimension (Theorem 4), the total dimension of the associated Brauer configuration algebra (Theorem 5), and the normalization constant (Theorem 6). In particular, one of the consequences of the corrected Brauer-quiver analysis is the formula
A fifth main contribution is entropic. We introduce a weighted distribution attached to the support-controlled multiplicity and valency data and distinguish from the outset between the vertex entropy and the layer entropy. We establish an exact decomposition of the vertex entropy by Hamming layers (Proposition 12), compute the layer weights explicitly (Proposition 11), and prove that the induced layer distribution is asymptotically concentrated on the middle Hamming layers (Theorem 7), while the contribution of any fixed maximal directed path is negligible in the limit (Proposition 14). As a consequence, the layer entropy satisfies a logarithmic asymptotic law (Theorem 8).
Finally, we study geometric consequences of the Boolean model transported through the support identification . Using coordinate projections, we prove a rigidity theorem for antipodal pairs: maximally separated pairs are unique and lose exactly one unit of Hamming distance under each coordinate deletion (Theorem 9). This provides a combinatorial analogue of Greenberger–Horne–Zeilinger (GHZ)-type fragility. In contrast, the first Boolean layer is shown to persist nontrivially under every coordinate projection (Proposition 15), reflecting a robustness pattern analogous to that of W-type configurations. We also prove that valency grows strictly along every maximal directed path in the Hasse diagram (Corollary 6), thereby linking the support-quiver orientation with the local support-controlled structure.
Taken together, these results show that the Boolean skeleton of the Grassmann algebra admits a Brauer-theoretic realization that is simultaneously combinatorial, geometric, and representation-theoretic. It yields a connected and computable family of support-defined Brauer-type configurations, a genuine associated standard Brauer configuration algebra, and a natural asymptotic entropy theory governed by the middle layers of the Boolean lattice.
2. Supports and the Map
The combinatorial core of our construction is controlled by the distinguished variables
while a small family of auxiliary symbols will be used only to improve the connectivity properties of the resulting Brauer-type configuration. The purpose of this section is to formalize the support map that extracts the Boolean content of a monomial label and to record the numerical data induced by this support. As will become clear throughout the paper, all support-controlled invariants relevant to our construction factor through this map.
Definition 1
(x-support and x-degree). Let , and let be a family of commuting variables. We also fix three additional symbols
which will be referred to as ghost variables. For any monomial label w built from the alphabet
we define its x-support by
and its x-degree by
The map forgets all ghost contributions and retains only the information carried by the distinguished variables . In this sense, it extracts from each monomial label its underlying Boolean support in , where . Different monomial labels may therefore determine the same x-support, and from the point of view of the present theory, they are combinatorially indistinguishable whenever their x-supports agree.
Definition 2
(Valency and multiplicity induced by ). For any vertex label w, we define its valency by
We also define its multiplicity by
These two functions are designed so that the entire numerical structure of the family is governed by the Boolean size of the support. In particular, both and depend only on the subset , and in fact only on its cardinality. Thus, the combinatorics of the construction is naturally stratified by Hamming layers: all labels with the same x-degree contribute identically to the support-dependent counts that appear later in the dimension formulas and entropy computations.
It is useful to make this observation explicit.
Remark 1
(Support classes and Boolean layers). For each subset , one may consider the corresponding support class
These classes are indexed by the Boolean lattice , and the quantity records precisely the Hamming layer to which belongs. Consequently, the support map organizes all monomial labels into Boolean strata
Later, this stratification will reappear in the quiver description, in the formulas for global invariants, and in the asymptotic concentration of entropy on the middle layers.
Lemma 1
(Support invariance of local data). If w and are two monomial labels such that
then
In particular, valency and multiplicity depend only on the x-support of a label.
Proof.
By Definition 2, both and depend only on
Hence, if , then , and therefore
This proves the claim. □
The preceding definitions already isolate the basic principle behind the paper: the true invariant content lies in the x-support, whereas the ghost variables serve only an auxiliary structural role.
Remark 2
(What ghosts can and cannot change). The map ignores all ghost symbols. Consequently, membership in polygons, all valencies, and all multiplicities depend only on . Ghost variables may influence the way in which we realize the configuration as a connected diagram, but they do not modify the Boolean support classes, nor any of the numerical data governed by those classes. In particular, two labels with the same x-support always have the same valency and the same multiplicity, regardless of their ghost content.
The separation between support data and ghost data is one of the organizing principles of the paper. It allows us to enforce connectedness at the level of the Brauer-type configuration without altering the support-controlled invariants that encode the underlying Boolean geometry. In the next section, we implement this principle in the construction of the connected family and prove that the auxiliary ghost variables leave the -governed combinatorial data unchanged.
3. The Vertex Set and the Polygonal Structure
We now define the finite family of vertex labels from which our Brauer-type configuration will be built. The construction starts from a fixed base layer in three distinguished variables , together with the three ghost variables introduced in Section 2. For arbitrary , this base layer is then extended by multiplication with monomials in the remaining variables . In this way, the resulting vertex set retains a rigid ghost component while its x-support ranges over the full Boolean lattice.
Definition 3
(Base labels at ). Fix the ghost set
once and for all. We define the base family of labels by
The set is the seed from which all higher-dimensional vertex sets are generated. Its elements are chosen so that the ghost contribution is completely controlled and the distinguished variables already exhibit the support patterns that will later propagate through all Boolean layers.
Definition 4
(Vertex set for general n). Let , and set
For each subset , write
We define the vertex set
This description makes the structure of transparent: every vertex is obtained by taking one of the eight base labels in and adjoining an arbitrary monomial in the variables . Since the choice of and the choice of are independent, we immediately obtain the cardinality formula
Thus, the total number of vertices agrees exactly with the size of the Boolean lattice , in accordance with the support-based interpretation developed in the previous section.
This cardinality match is not accidental: it reflects the fact that the construction has been designed so that the x-support of vertex labels ranges over all subsets of .
The special role of the ghost variables already appears in the existence of a unique vertex with empty x-support.
Proposition 1
(Unique vertex with empty x-support). In , the unique label with is
Consequently,
Proof.
Let satisfy . By Definition 4, we may write
Since does not divide w for any , in particular no variable with divides w. Hence , so .
It remains to determine which element of has empty x-support. Inspecting the list in Definition 3, we see that every element except contains at least one distinguished variable . Therefore
which proves uniqueness.
For the multiplicity sum, Definition 2 gives
Since , it follows that
□
We now define the polygon family. One polygon contains all vertices, while each distinguished variable determines a support-selected subfamily.
Definition 5
(Polygon family). We define
where
and, for each ,
Thus, consists of exactly polygons: one global polygon , together with one support polygon for each distinguished variable.
Remark 3.
For every , the set of polygons containing w is completely determined by : namely, always, and if and only if . Hence, the incidence pattern of the configuration is entirely encoded by the Boolean support and, in particular, is independent of the ghost content of the labels.
By construction, the family depends only on the x-support structure of the vertex labels. In particular, the ghost variables do not alter polygon membership, since they are invisible to the map .
This support-based definition of polygons is the mechanism through which the Boolean geometry of enters the Brauer-type setting. In the next section, we use it to describe incidences explicitly and to establish the connectedness properties of the resulting configuration.
Proposition 2
(Boolean identification via the support map). Let . The map
is a bijection.
Proof.
We construct an explicit inverse
Let . Write S uniquely as
We define a base label by
This is well defined because each subset of appears exactly once in the list, and each chosen label belongs to ; see Definition 3.
Now define
By Definition 4, we have .
We first verify that . By construction, the label has x-support exactly , while the factor contributes precisely the variables indexed by . Hence
so
Conversely, let . By Definition 4, we may write
Set
Then
records exactly which of the variables divide the base label v, while
By construction of the correspondence , we have
Therefore
Thus , and is bijective. □
4. Boolean Support Data and the Support Quiver
The support map
constructed in Proposition 2, transports the Boolean rank structure of to the vertex set . This yields a canonical directed quiver attached purely to the support geometry of the family. We emphasize from the outset that this quiver is not the standard Brauer quiver of a Brauer configuration algebra. It is instead the Boolean support quiver naturally induced by the support relation.
Definition 6
(Support covering relation). Let . We say that is a support successor of w, and write
if
Equivalently, there exists a unique such that
For notational convenience, we shall write
for the Boolean support quiver attached to the family .
Definition 7
(Boolean support quiver). We define the Boolean support quiver as follows:
- its vertex set is ;
- for every pair , there is an arrowif and only if .
Proposition 3
(Support quiver as an oriented Hasse diagram). Under the Boolean identification
the support quiver is isomorphic to the Hasse diagram of the Boolean lattice , oriented by increasing cardinality.
Proof.
Let , and write
By Definition 6, there is an arrow in if and only if
which is exactly the covering relation in the Boolean lattice . Since the orientation is induced by increasing x-degree, it coincides with the standard rank orientation of the Hasse diagram. This proves the claim. □
Remark 4.
The quiver is the correct combinatorial object for the Boolean geometry carried by the support map. It encodes the hypercube structure on , but by construction it depends only on support inclusions and not on cyclic successor relations at polygons. For this reason, should be regarded as a support-theoretic object rather than as the standard Brauer quiver of the associated Brauer configuration algebra.
5. A Canonical Standard Brauer Configuration Structure
We now complete the support-defined family into a genuine Brauer configuration in the standard sense by specifying an explicit cyclic ordering of the polygons incident with each vertex. This is the additional structural datum required in order to speak unambiguously about the associated Brauer configuration algebra and its Brauer quiver.
Definition 8
(Incident polygon set at a vertex). For , define
By Definition 5 and Remark 3,
In particular,
Definition 9
(Canonical local cyclic ordering). Let , and write
We define the cyclic ordering on by
If , that is, if , then , and is the unique cyclic ordering on a singleton.
Definition 10
(Canonical orientation datum). Let
We call the canonical support-compatible orientation on .
Proposition 4
(Polygon sizes and nontriviality). For every , the polygons in satisfy
In particular, every polygon in is nonempty and contains at least two vertices.
Proof.
By Definition 5,
so
by Definition 4.
Fix . Under the Boolean identification
the polygon corresponds exactly to the family of subsets of containing i. There are such subsets, since the remaining coordinates may be chosen arbitrarily. Therefore
Since , we have and . Hence, every polygon is nonempty and has at least two vertices. □
Theorem 1
(Standard Brauer configuration). For every , the datum
is a connected reduced Brauer configuration in the standard sense. In particular, the Brauer configuration algebra
associated with is well defined.
Proof.
We show that the support-defined family constructed in the previous sections satisfies all the requirements of a connected reduced Brauer configuration once equipped with the canonical orientation datum .
First, both the vertex set and the polygon family are finite. Indeed, by Definition 4, the set consists of all labels of the form
so
On the other hand, by Definition 5,
and therefore . Thus, the underlying combinatorial data is finite.
Next, each polygon is a finite multiset of vertices. In fact, in the present construction, each polygon is simply an ordinary finite subset of , so all vertex occurrences inside a given polygon have multiplicity one at the level of incidence. More precisely,
Hence, every polygon is a well-defined finite collection of vertices of . Moreover, every vertex belongs to at least one polygon, because every lies in the global polygon . In particular, the incidence relation is everywhere defined.
We also need the polygons themselves to be nontrivial. This follows from Proposition 4, which shows that
Since , each of these cardinalities is at least 2, so every polygon contains at least two vertices. Thus, no polygon degenerates to an empty or singleton incidence object.
The multiplicity function is already part of the support-controlled structure. By Definition 2, we have
This defines a map
so the multiplicity datum required in the definition of a Brauer configuration is fixed.
It remains to specify the orientation. For each , the set of incident polygons is
by Definition 8. Writing
Definition 9 endows with the cyclic ordering
If , then , and there is a unique cyclic ordering on this singleton. Consequently, for every vertex , we have a well-defined cyclic ordering of the polygons incident with w. Collecting these orderings over all vertices yields the global orientation datum
In particular, since the family has no truncated vertices by Proposition 7, this gives an orientation in the standard Brauer-configuration sense on all nontruncated vertices.
At this point, all local data of a Brauer configuration have been specified. We now turn to the global structural properties. The connectedness follows from Theorem 3: the incidence graph of is connected because every vertex label is incident with the global polygon , and every support polygon is linked to through a vertex containing . Hence, the Brauer configuration determined by these data is connected.
Similarly, the reducedness follows from Proposition 7. Indeed, that proposition shows that for every one has
so no vertex is truncated. Therefore, the resulting Brauer configuration is reduced.
Finally, because the family is connected and reduced and all the defining data of a standard Brauer configuration have now been explicitly specified, the datum
is a connected reduced Brauer configuration in the standard sense. It follows that the associated Brauer configuration algebra is mathematically unambiguously determined by the data of . □
Remark 5.
The standard Brauer configuration and the support quiver are attached to the same support-defined family, but they encode different kinds of structure. The first uses the canonical cyclic orderings and gives rise to the standard Brauer configuration algebra. The second records only the Boolean covering relation on supports.
Definition 11
(Associated Brauer configuration algebra). For , we write
for the Brauer configuration algebra associated with the standard Brauer configuration .
6. The Standard Brauer Quiver
We now define the genuine Brauer quiver attached to and compute its arrow multiplicities explicitly. As expected from the referee’s observation, this quiver is different from the Boolean support quiver .
Definition 12
(Standard Brauer quiver). The Brauer quiver of is defined as follows:
- its vertices are in bijection with the polygons in , namely
- for each vertex , and for each polygon , if is the successor of V in the cyclic ordering , then contains one arrow
Theorem 2
(Explicit description of the standard Brauer quiver). For every , the Brauer quiver has vertex set
and its arrows are determined as follows:
- (i)
- there is exactly one loop at ;
- (ii)
- for each , the number of arrows is
- (iii)
- for each , the number of arrows is
- (iv)
- for every pair , the number of arrows is
- (v)
- no other arrows occur.
Proof.
Recall first that the vertices of are indexed by the polygons of , namely
By Definition 12, the arrows of are obtained from the cyclic orderings of the polygons incident with each vertex . Thus, the entire problem reduces to understanding, for a fixed w, which successor relations are produced by the canonical orientation .
Let , and write
Then, by Definition 9, the cyclic ordering at w is
It follows immediately that the arrows contributed by the single vertex w are exactly
In other words, each vertex w contributes the directed cycle obtained by reading the elements of in increasing order, inserting at the beginning and at the end.
This description already shows that every arrow in must be of one of the following three types:
We now count the number of occurrences of each type.
We begin with the loop at . Such a loop can only arise when the incident polygon set at a vertex w is the singleton , because only in that case does the successor of equal itself. By Proposition 1, there is exactly one vertex of with empty support, namely
For this vertex one has
and therefore the cyclic ordering at contributes exactly one loop
No other vertex can contribute such a loop, because every vertex with nonempty support is incident with and at least one further polygon . This proves (i).
Next fix . An arrow is contributed by a vertex w if and only if is the first support polygon after in the cyclic order at w. By the form of , this happens precisely when i is the smallest element of . Equivalently, the support of w must satisfy the following conditions:
while the membership of the elements of is arbitrary. Thus, once i is forced to belong to the support and the indices are forced to stay out, the remaining indices can be chosen freely. Hence, the number of such supports, and therefore the number of arrows , is
This proves (ii).
We now count the arrows . Such an arrow occurs precisely when is the last support polygon before returning to in the cyclic order at w. This is equivalent to saying that i is the largest element of . Therefore, the support must contain i, must contain no element of , and may contain an arbitrary subset of . The number of possibilities is therefore
which proves (iii).
Finally, let . We claim that an arrow occurs if and only if i and j both belong to and j is the immediate successor of i in the increasing ordering of . By the explicit description of the cyclic order, this means exactly that
At the same time, the indices smaller than i may be chosen arbitrarily, and the indices larger than j may also be chosen arbitrarily. Therefore:
- each subset of may be added freely, giving choices;
- the interval contributes no choice, since all its elements must be absent;
- each subset of may be added freely, giving choices.
- Multiplying these independent choices, we obtain
It remains only to justify that no further arrows can appear. But this follows immediately from the form of the local cyclic ordering:
Every arrow either starts at , ends at , or connects two support polygons whose labels occur consecutively in strictly increasing order. In particular, no arrow with can occur, and no arrow of any other type is compatible with the canonical cyclic ordering. This proves (v) and completes the proof. □
Corollary 1
(The two quivers are different). For every , the Brauer quiver is not isomorphic to the support quiver .
Proof.
The two quivers are built on fundamentally different vertex sets. By Definition 12, the vertices of are indexed by the polygons of , and hence
On the other hand, by the definition of the support quiver, the vertices of are precisely the elements of , so
Since for every , the two quivers cannot be isomorphic. □
Remark 6.
Corollary 1 is the precise mathematical reason why the Boolean Hasse diagram should not be identified with the standard Brauer quiver. The support quiver records the geometry of the Boolean lattice on vertex labels, whereas the Brauer quiver records successor relations among polygons induced by the canonical cyclic orderings.
7. Incidence Structure, Connectedness, and Ghost Invariance
We now turn from the set-theoretic description of the family to its incidence structure and to the support-controlled properties that will later enter the algebraic computations. The main goal of this section is to establish connectedness of the incidence graph, reducedness of the underlying configuration, and invariance of the support-controlled data under ghost relabelings. We also record that the Boolean support quiver is loop-free. This last property concerns the support quiver only and should be kept separate from the standard Brauer quiver introduced later. These facts provide the structural input needed for the global formulas of Section 9. More broadly, this passage from combinatorial incidence data to algebraic structure is typical of Brauer graph and Brauer configuration theory, where geometric and combinatorial realizations play an organizing role; see [18,19]. It is also compatible with more recent Brauer-type extensions toward weighted surface settings; see [20].
7.1. Incidence Graph and Local Incidence Counts
We begin by encoding the configuration in the usual bipartite way.
Definition 13
(Incidence graph). The incidence graph is the bipartite graph whose vertex set is
and where a vertex label is joined to a polygon if and only if
The support-based description of polygon membership immediately determines the incidence degree of every vertex label.
Proposition 5
(Incidence degree equals valency). For every , the number of polygons of containing w is
Equivalently, the degree of w in the incidence graph is equal to its valency.
Proof.
By Definition 5, every label belongs to the global polygon
Moreover, for each , one has
Therefore the polygons containing w are exactly
Hence, their number is
by Definition 2. This proves the claim. □
Remark 7.
Each support polygon is nonempty. Indeed, if , then
so . If , then
hence .
7.2. Connectedness and Component Count
The presence of the global polygon makes connectedness completely transparent.
Theorem 3
(Connectedness of the configuration). For every , the incidence graph is connected. In particular, the Brauer-type configuration is connected.
Proof.
Let . Since , every vertex label w is adjacent to the polygon in the incidence graph. Thus, all vertices in lie in the same connected component as .
Now, let . If , there is nothing to prove. Otherwise
for some . By Remark 7, the polygon contains at least one label . Since every such label is adjacent to , the polygon is connected to through the path
Therefore, every node of lies in the same connected component as , and hence is connected. □
Corollary 2
(Component count). Let denote the set of connected components of the incidence graph . Then
Proof.
This is immediate from Theorem 3. □
7.3. Ghost Invariance
We now make precise the sense in which ghost variables improve connectivity without altering the support-controlled combinatorics of the family.
Definition 14
(Support-preserving ghost relabeling). Let be another family of monomial labels built from the same distinguished variables and some auxiliary ghost symbols. We say that is a support-preserving ghost relabeling of if there exists a bijection
such that
The corresponding polygon family is defined from by the same support rules:
Proposition 6
(Ghost invariance of support-controlled data). Let be a support-preserving ghost relabeling of in the sense of Definition 14. Then, the following quantities are preserved under the bijection θ:
- (i)
- Polygon membership;
- (ii)
- Valency and multiplicity;
- (iii)
- The Boolean stratification by x-degree;
- (iv)
- The support quiver, hence also the Hasse-diagram realization.
- Consequently, all invariants depending only on the x-support structure are unchanged by ghost relabeling.
Proof.
The defining property of a support-preserving ghost relabeling is that
Thus, leaves unchanged the Boolean support carried by each vertex label. Since all the data under consideration are defined purely in terms of , their invariance follows from this identity.
We first consider polygon membership. By Definition 5, a label belongs to the polygon if and only if . On the relabeled side, by the definition of , the vertex belongs to if and only if . Since , we obtain
for every . Moreover, for every , and by definition . Hence, polygon membership is preserved.
The same observation immediately yields the invariance of valency and multiplicity. Indeed, by Definition 2, both and depend only on the cardinality of the support, that is, only on
Since , one has
and therefore
In particular, the x-degree of a label is unchanged under . This means that the partition of the vertex set into Boolean layers
is carried bijectively onto the corresponding partition of . Hence, the Boolean stratification by x-degree is preserved.
Finally, we examine the support quiver. By Definition 6, there is an arrow
in if and only if
Because preserves supports exactly, this condition holds for the pair if and only if it holds for . Therefore
in the relabeled support quiver. It follows that induces an isomorphism between the two support quivers. Since the Hasse-diagram realization is obtained from the support quiver via the identification with the Boolean lattice, it is preserved as well.
Thus, every datum determined purely by the x-support, including polygon membership, valency, multiplicity, Boolean layer structure, and the support quiver, remains unchanged under ghost relabeling. This proves the claim. □
Remark 8.
Proposition 6 makes precise the ghost principle underlying the paper: ghost variables may change the presentation of the labels while remaining compatible with a connected realization of the configuration. However, they do not alter the Boolean support geometry that governs incidences, valencies, multiplicities, quiver structure, and the global formulas derived later.
Remark 9
(On the role of the third ghost variable). The present construction uses three ghost variables in order to keep the base family symmetric with respect to the distinguished variables . We do not claim here that three ghost variables are minimal for obtaining a connected realization with the same support-controlled invariants. The question of whether an analogous construction can be carried out with only two ghost variables is a natural minimality problem, but it lies beyond the scope of the present paper.
7.4. Reducedness and Loop-Freeness of the Support Quiver
We next verify two structural properties required for the standard formulas used in Section 9.
Definition 15
(Truncated vertex). A vertex is called truncated if
Following the standard convention for Brauer configurations, we call reduced if it has no truncated vertices.
Proposition 7
(Absence of truncated vertices). For every , the configuration has no truncated vertices. In particular, it is reduced.
Proof.
Let .
If , then by Proposition 1 we have
Hence, and , so
If , then . By Definition 2,
Therefore
In all cases,
Thus, no vertex is truncated, and is reduced. □
Finally, we record the absence of loops in the support quiver.
Proposition 8
(Loop-freeness of the support quiver). The support quiver has no loops.
Proof.
Suppose there were a loop at some vertex . By Definition 7, this would mean that . But by Definition 6, the relation would require
which is impossible. Therefore, no loop can occur in . □
Corollary 3
(Support-level structural summary). For every , the family has the following support-level properties:
- (i)
- Its incidence graph is connected;
- (ii)
- It has no truncated vertices, hence it is reduced;
- (iii)
- Its support quiver is loop-free.
- Equivalently,
Proof.
Statements (i), (ii), and (iii) are exactly Corollary 2, Proposition 7, and Proposition 8, respectively. □
Remark 10.
Proposition 8 concerns only the Boolean support quiver . By contrast, the standard Brauer quiver attached to the Brauer configuration is a different object and, by Theorem 2, it contains exactly one loop at the vertex . This distinction is essential when the standard formulas for Brauer configuration algebras are applied in the next section.
8. Inductive Structure via the Lift Map
We now make explicit the recursive structure of the family as the parameter n increases. From the Boolean point of view, passing from to amounts to introducing one new coordinate, namely the element n, and splitting the power set into those subsets that avoid n and those that contain it. On the level of vertex labels, the same phenomenon is realized by adjoining the new distinguished variable . In this way, decomposes into two canonically related layers: a first layer identified with , and a second one obtained from it by multiplication by .
Definition 16
(Lift map). For , we define the lift map
The terminology is natural: the map lifts a label from dimension to dimension n by adjoining the new variable . Since the base family remains unchanged and only the monomial factor in the variables is modified, one expects this operation to describe exactly the second Boolean layer in dimension n.
Proposition 9
(Two-layer decomposition). For each , the vertex set decomposes as
Moreover, is a bijection from onto the second layer
Proof.
By Definition 4, every element of is of the form
Thus, the structure of is completely controlled by the choice of the subset . We therefore partition according to whether or not the index n belongs to A:
If , then necessarily , and hence
This identifies the first part of the decomposition with the old layer .
Now suppose that . Then, A can be written uniquely as
Therefore
with . This shows that every label in whose support contains n lies in the image of the lift map. Hence
The reverse inclusion is immediate from the definition of , so we obtain
It remains to prove that this union is disjoint. If , then by construction no factor occurs in w. On the other hand, every element of is divisible by . Hence
and the decomposition is indeed a disjoint union.
Finally, the image of is exactly the set of vertices such that . Indeed, by definition every lifted label is divisible by , so . Conversely, if satisfies , then the argument above shows that for a unique label . Thus, is a bijection from onto the second layer
This proves the claim. □
Remark 11.
Under the Boolean identification of Proposition 2, the two-layer decomposition of corresponds exactly to the standard partition
In this correspondence, the lift map acts by adjoining the element n to the underlying subset. Thus, the recursive structure of is nothing but the support-level shadow of the elementary Boolean decomposition of .
The first low-dimensional instances of this decomposition are displayed explicitly in Appendix A. In particular, the cases and illustrate how the successive lift operations produce two and four copies, respectively, of the base family . Moreover, the preceding decomposition is reflected immediately in the support map and in the numerical data derived from it.
Proposition 10
(, x-degree, and valency under the lift). For every , one has
and consequently
Proof.
Let . By definition,
Since the factor appears explicitly in this product, we certainly have
We claim that no other support coordinate is altered. Indeed, for every , the variable divides if and only if it already divides w, because multiplication by introduces no new factor with , and it does not remove any existing divisibility by such a variable. Therefore
Together with , this proves that
Taking cardinalities on both sides, we obtain
because for every .
Finally, by Definition 2,
Applying this identity to and using the formula just established for the x-degree, we get
This proves the proposition. □
9. Global Invariants
Having now distinguished the standard Brauer configuration
from the Boolean support quiver, we may compute the main global invariants of the associated Brauer configuration algebra . Most of the relevant quantities remain support-controlled: since the multiplicity and valency functions depend only on the x-support, all global sums reduce to binomial counts over the Boolean layers of . The only genuinely Brauer-quiver-theoretic datum entering the center formula is the number of loops in the standard Brauer quiver , which must be kept separate from the loop-free property of the Boolean support quiver. This distinction is essential for the correctness of the formulas below.
This emphasis on explicit support-controlled invariants is consistent with other combinatorial Brauer families in which numerical invariants can be derived directly from the defining data; compare [22,25].
9.1. Center Dimension
Since is a connected reduced Brauer configuration by Theorem 1, we may apply the standard center-dimension formula for Brauer configuration algebras in the connected reduced case; see [21]:
In our situation, the relevant terms are explicitly known. By Definition 5,
while Definition 4 gives
Moreover, the incidence graph is connected by Corollary 2, so
The multiplicity sum was computed in Proposition 1, namely
Finally, by Theorem 2, the standard Brauer quiver contains exactly one loop, namely the loop at the vertex . Therefore
Substituting these data into (3) yields the following formula.
Theorem 4
(Center dimension). For every ,
Proof.
Using the identities above in (3), we obtain
This proves the claim. □
9.2. Total Dimension of the Algebra
We next use the standard dimension formula for Brauer configuration algebras:
Because the valency depends only on the Hamming layer , the vertex sum in (4) reduces to a weighted binomial moment over the Boolean lattice.
Lemma 2
(First and second binomial moments). For every , one has
Proof.
Starting from the binomial identity
we differentiate once to obtain
Multiplying by t and setting gives
Differentiating a second time yields
Multiplying by and setting gives
Since , it follows that
□
Theorem 5
(Total dimension). For every , the total dimension of the associated algebra is
Proof.
By Definition 2,
and hence
Under the Boolean identification
from Proposition 2, there are exactly vertices of x-degree k. Therefore
Applying Lemma 2, we obtain
Since , Formula (4) gives
as required. □
9.3. Vertex Weights, Layer Weights, and Entropy
We now turn to the weighted distribution induced by the support-controlled multiplicity and valency data. Since the referee correctly observed that vertex entropy and layer entropy are different quantities, we treat them separately from the outset.
We begin with the normalization constant
and the corresponding vertex weights
The associated vertex entropy is
For notational continuity, one may also write
The first step is to compute explicitly.
Theorem 6
(Closed form for ). For every ,
Proof.
We split the sum in (5) into the contribution of the unique vertex with empty x-support and the contribution of all remaining vertices.
By Proposition 1, the unique vertex with empty x-support is
Since , , and , its contribution is
Now let with . Then
For each k, there are exactly such vertices, so
Using Lemma 2, we obtain
while
Substituting back gives
as claimed. □
To organize the weighted distribution macroscopically, we group the vertex weights by Hamming layers. For each , define the k-th layer weight by
Thus
The normalized layer probabilities are then
These define a probability distribution on the set of Hamming layers, and the corresponding layer entropy is
Proposition 11
(Closed form for the layer weights). For every , the layer weights satisfy
Consequently,
Proof.
For , Proposition 1 shows that the unique vertex of x-degree zero is
Since and , we obtain
Now fix . Under the Boolean identification
there are exactly vertices with . For each such vertex,
Hence
Summing over all layers yields the stated decomposition of . □
Remark 12
(Fixed multiplicity parameter at the zero-support vertex). One may replace the distinguished multiplicity value at the unique vertex with empty x-support by an arbitrary fixed parameter , while keeping for all vertices with nonempty support. In that case, the normalization constant becomes
and the only layer weight that changes is
Hence, the induced layer probabilities satisfy
For every fixed m, this modifies the layer distribution only by a lower-order term, so the middle-layer concentration and the logarithmic asymptotic law for the layer entropy remain unchanged as .
Proposition 12
(Exact decomposition of vertex entropy by layers). Let
Then
Equivalently,
Proof.
For each k, all vertices in the k-th Hamming layer carry the same individual weight. Indeed, if , then
Since there are vertices in the k-th layer and the total weight of that layer is , each vertex in that layer has weight
Therefore, grouping the sum in (7) by layers, we obtain
The first sum is exactly , which proves the claim. □
Corollary 4
(Explicit form of the layer distribution). For every ,
Moreover,
Proof.
This is immediate from Proposition 11 and the definition of . □
Remark 13.
Proposition 12 is the precise relation between the two entropies. The layer entropy measures the macroscopic distribution of mass across Hamming layers, whereas the vertex entropy also includes the conditional contribution coming from the multiplicity of vertices inside each layer. In particular, these two quantities should not be identified.
The weights differ from the usual binomial distribution only by the additional factor , which is of polynomial size in n. As a consequence, the dominant mass still lies in the middle Hamming layers.
Proposition 13
(Comparison with the binomial law). Let
be the distribution. Then, for ,
In particular, for all ,
uniformly in k.
Proof.
By Corollary 4 and Theorem 6,
Factoring out from the denominator gives
Therefore
which proves (11). The asymptotic form follows immediately. □
We now formalize the concentration of the layer distribution on the middle Hamming layers.
Theorem 7
(Concentration on the middle layers). Fix . Then
In other words, the layer distribution is asymptotically concentrated on the middle Hamming layers.
Proof.
By Proposition 13, for ,
Since , we have
for all sufficiently large n. Therefore
The right-hand side tends to 0 by the standard concentration of the binomial distribution . Since
the full sum also tends to 0. This proves the claim. □
The preceding result shows that the layer distribution is asymptotically governed by the bulk of the Boolean lattice. In particular, any fixed family of extremal vertices or paths carries only a negligible fraction of the total weight.
To make this explicit, consider a maximal directed path in the Hasse diagram
Such a path meets exactly one vertex in each Hamming layer.
Proposition 14
(Negligible mass of a fixed maximal path). Let
be the vertex set of any fixed maximal directed path from ⌀ to in the Hasse diagram of . Then
In particular, the contribution of any fixed long diagonal is asymptotically negligible.
Proof.
Along such a path, there is exactly one vertex of each x-degree k, . Hence
Indeed, the unique degree-zero vertex contributes 2, and for the unique vertex on the path in layer k has multiplicity 1 and valency . Therefore
On the other hand, by Theorem 6,
Thus
and the right-hand side tends to 0 exponentially fast as . □
We can now pass to the asymptotics of the layer entropy. Since the distribution differs from the binomial law only by a multiplicative factor that is asymptotically 1 on the central window , the leading asymptotic coincides with that of the entropy of .
Theorem 8
(Asymptotic law for the layer entropy). As ,
Proof.
Recall that
where is given by Corollary 4. Let
denote the binomial distribution. By Proposition 13, for ,
Fix , and define the central window
By Theorem 7, the total -mass outside tends to 0 as , and similarly the total -mass outside tends to 0.
Now let . Then
uniformly on , and therefore
Hence
uniformly for .
Using the expansion
valid for small , we conclude that on the central window
Since the contribution from the complement of is , it follows that
The right-hand side is the entropy of the binomial distribution , whose classical asymptotic form is
see, for instance, ref. [27]. Therefore
as claimed. □
Corollary 5
(Middle-layer dominance). As , the layer entropy is asymptotically governed by the middle Hamming layers, while any fixed maximal path contributes a vanishing fraction of the total vertex weight.
Proof.
The first statement is a reformulation of Theorem 7, while the second follows from Proposition 14. □
10. Boolean-Hypercube Consequences of the Support Identification
In this section, we exploit the Boolean identification
from Proposition 2 in order to transport standard geometric features of the Boolean lattice to the support-defined vertex set . Thus, the results proved below should be understood as consequences of the hypercube structure carried to through the support map, rather than as intrinsic properties of the standard Brauer quiver itself. This distinction is important: the standard Brauer quiver and the Boolean support quiver are different objects, as shown in Corollary 1, whereas the present section concerns the geometry of the Boolean support model.
Via the identification
the support quiver becomes the Hasse diagram of the Boolean lattice and hence inherits the natural metric and projection structure of the n-dimensional hypercube. This viewpoint allows us to formalize two complementary phenomena: the rigidity of antipodal pairs under coordinate deletion, and the persistence of low-degree layers under the same operation.
In particular, the geometric object underlying the discussion is the hypercube viewed both as a ranked poset and as a distance-regular graph, two perspectives that have been extensively studied in the literature; see [10,11].
10.1. Hamming Distance and Algebraic Locality
We equip with the Hamming distance
where Δ denotes symmetric difference. Since the Hasse diagram of is the n-dimensional hypercube, this metric counts the minimal number of edges in the underlying undirected graph needed to connect the vertices S and T. In particular,
if and only if S and T differ by exactly one coordinate, equivalently, if and only if they are joined by a single edge in the Hasse diagram.
Transported back to through the map , this metric measures a form of support-level locality: vertices lying in nearby Boolean layers are connected by short chains of covering relations in the support quiver, whereas vertices that are far apart require many successive support changes. The extremal case is realized by antipodal pairs, whose supports differ in every coordinate.
10.2. Coordinate Projections
For each , define the coordinate projection
This operation deletes the i-th coordinate and may be viewed as a purely combinatorial analogue of removing one subsystem from an n-partite configuration.
The effect of this operation on Hamming distance is completely explicit.
Lemma 3
(Hamming distance under projection). For all and all ,
Proof.
By definition of Hamming distance,
Now deleting the coordinate i removes that element from the symmetric difference exactly when , and leaves the symmetric difference unchanged otherwise. Therefore
and hence
Since , the claimed identity follows. □
This lemma will be the basic tool in what follows. It shows that the effect of deleting one coordinate is completely controlled by whether that coordinate contributes to the original symmetric difference.
10.3. Antipodal Rigidity Under Projection
For every , let
denote the complementary subset. The pair is antipodal in the hypercube, and satisfies
since .
The next theorem records the rigidity of such antipodal pairs under coordinate deletion.
Theorem 9
(Antipodal rigidity under projection). Let and let be an antipodal pair in . Then, the following statements hold.
- (i)
- Uniform loss under projection. For every ,
- (ii)
- Uniqueness at maximal distance. If satisfiesthen necessarily
- (iii)
- Strict additivity across coordinate partitions. For every partitionone hasMoreover, both summands are strictly positive whenever and .
Proof.
Since , every coordinate belongs to the symmetric difference. Thus, for every ,
Applying Lemma 3, we obtain
which proves (i).
For (ii), assume that satisfies . Then
But , and the ambient set itself has cardinality n. Therefore , which is equivalent to
This proves uniqueness of the antipode at maximal distance.
Finally, let be a partition. Since A and B are disjoint and cover , the symmetric difference decomposes as the disjoint union
Taking cardinalities yields
It remains to prove the strict positivity of the two summands under the stated nonemptiness assumptions. If , then
and therefore
Consequently,
The same argument with B in place of A gives
whenever . This proves (iii). □
Remark 14
(GHZ-type interpretation). The preceding theorem shows that antipodal pairs are the unique maximally separated pairs in the Boolean geometry, and that every coordinate deletion lowers their Hamming distance by exactly one. At a purely combinatorial level, this behavior mirrors the fragility usually associated with GHZ-type correlations under subsystem loss. We emphasize, however, that the present result is entirely discrete and combinatorial: the GHZ terminology is used only as a structural analogy.
10.4. Robust Low-Degree Layers Under Projection
At the opposite end of the Boolean lattice, low-degree layers behave in a markedly different way under coordinate deletion. The simplest case is the degree-one layer
Unlike antipodal pairs, which lose one unit of distance under every projection, this layer retains a nontrivial part of its structure after removing any single coordinate.
For convenience, when working on we denote by
its degree-one layer.
To compare the image of with a layer inside , we use the canonical order-preserving bijection
This induces a bijection on power sets
Proposition 15
(Robustness of the degree-one layer). For every ,
In particular, removing any coordinate does not collapse the entire degree-one layer to a single vertex.
Proof.
Fix . For each , one has
Therefore
Applying , we obtain
Since is a bijection, the family of singletons obtained in this way is exactly the family of all singleton subsets of . Hence
which proves the claim. □
Remark 15
(W-type interpretation). In contrast with antipodal pairs, the degree-one layer survives coordinate deletion in a nontrivial way: only one vertex collapses to ⌀, while the remaining singletons persist after the canonical order-preserving identification . This provides a combinatorial analogue of the robustness commonly associated with W-type configurations. As above, the terminology is interpretative rather than physical.
The preceding contrast between antipodal pairs and low-degree layers captures a qualitative dichotomy in the Boolean geometry transported to : global extremal structures are fragile under coordinate loss, whereas low-degree strata retain a visible remnant after projection. This complements the entropy analysis of Section 9, where the dominant contribution arises from the intermediate Hamming layers rather than from extremal vertices.
10.5. Valency Growth Along Maximal Directed Paths
A further transported consequence of the Boolean model is that valency increases monotonically along every maximal directed path in the Hasse diagram. This is immediate from the formula , but it is useful to record it explicitly because it links the support-quiver orientation with the local support-controlled data.
Corollary 6
(Valency growth along maximal directed paths). Let
be any maximal directed path in the Hasse diagram from to . Then
and in fact
Proof.
Along each directed edge of the Hasse diagram, one passes from a set to a set for some . Therefore
Since , an immediate induction gives
Using the valency formula
we obtain
The strict inequalities
follow at once. □
11. Open Problems and Further Directions
The results established in this paper suggest several natural directions for further work. Some concern the internal structure of the Boolean support model and its relation to the standard Brauer configuration, while others point toward possible extensions beyond the Boolean setting.
Problem 1
(Support quiver versus Brauer quiver). The present family naturally carries two different quivers: the Boolean support quiver , which is the oriented Hasse diagram of , and the standard Brauer quiver , which is induced by the cyclic orderings of the polygons. Can one describe a deeper structural relationship between these two quivers? For example, is there a functorial or representation-theoretic mechanism that explains how support-level geometry is reflected in the Brauer-quiver combinatorics?
Problem 2
(Intrinsic characterization of extremal support paths). Maximal directed paths and antipodal geodesics arise naturally in the Boolean support quiver. Can these extremal support paths be characterized intrinsically in the support-defined family, without passing explicitly through the Boolean identification
Equivalently, is there a purely support-theoretic criterion detecting those paths whose total weight is asymptotically negligible but whose geometric rigidity is maximal?
Problem 3
(Brauer-theoretic projection operations). Is there a natural operation on standard Brauer configurations or on their associated algebras that plays the role of a coordinate projection? Such an operation should ideally reflect the dichotomy observed in Section 10: antipodal pairs should exhibit a rigid collapse phenomenon, while low-degree layers should remain partially visible after projection.
Problem 4
(Beyond the Boolean lattice). To what extent does the present construction extend to families whose support geometry is governed by combinatorial structures other than the Boolean lattice? One may ask, for example, whether analogous support-controlled Brauer configurations can be built from graded posets, simplicial complexes, partition structures, or graph-theoretic data, and whether such families admit explicit formulas for global invariants and entropy-type quantities. Existing constructions arising from Dyck paths, integer partitions, and graph-based Brauer analyses suggest that this is a natural direction to pursue; see [23,24,26].
Problem 5
(Entropy beyond the binomial regime). For the Boolean family , the layer distribution is asymptotically governed by a binomial law, while the vertex entropy decomposes into a layer contribution and an internal layer contribution. Is there a broader class of Brauer configurations for which analogous entropic decompositions are controlled by other probabilistic limit laws, such as Poisson, multinomial, or Gaussian-type regimes arising from different combinatorial geometries?
Problem 6
(Representation-theoretic meaning of middle-layer dominance). The entropy analysis shows that the dominant weight lies asymptotically in the middle Hamming layers. Is there a representation-theoretic or homological interpretation of this phenomenon inside the Brauer configuration algebras ? In particular, can the middle layers be detected through module-theoretic, homological, or categorical invariants attached to the algebra?
Remark 16.
From a broader perspective, the Boolean family developed here suggests that explicit Brauer configuration algebras may serve as a meeting point between combinatorial representation theory, discrete geometry, and entropy-type asymptotics. The existence of other Brauer families arising from recursive, graph-theoretic, and partition-based combinatorics supports the expectation that the present Boolean model is part of a wider phenomenon; see [23,24,25,26]. Exploring this bridge beyond the present setting remains an open and potentially fruitful direction.
Main Notation
For the reader’s convenience, we summarize here the principal notation used throughout the paper.
| Notation | Meaning |
| The standard finite index set. | |
| The Boolean lattice, that is, the power set of . | |
| The Boolean support family associated with the Grassmann-inspired support construction in dimension n. | |
| The support-defined family consisting of the vertex set and polygon family. | |
| The standard Brauer configuration | |
| The vertex set of the family. | |
| The polygon family of the construction. | |
| The fixed base family of monomial labels used to generate for all . | |
| The set of indices corresponding to the variables adjoined to the base layer. | |
| The monomial attached to a subset , with . | |
| The x-support of a monomial label w, defined by | |
| The x-degree of a monomial label w, given by | |
| The multiplicity of a vertex label w, defined by | |
| The valency of a vertex label w, defined by | |
| The Boolean identification map, sending each vertex label to its x-support. | |
| The Boolean support quiver, identified with the directed Hasse diagram of . | |
| The standard Brauer quiver attached to the Brauer configuration . | |
| The canonical orientation datum on . | |
| The lift map , adjoining the new variable . | |
| The Hamming distance on the Boolean lattice. | |
| The coordinate projection deleting the i-th coordinate from a subset . | |
| The canonical order-preserving bijection used to compare with . | |
| The normalization constant associated with the weighted vertex distribution. | |
| The normalized weight assigned to a vertex . | |
| The total weight of the k-th Hamming layer, given by | |
| The normalized probability assigned to the k-th Hamming layer. | |
| The vertex entropy of the weighted distribution on . | |
| The entropy of the induced probability distribution on Hamming layers. | |
| The Brauer configuration algebra associated with . |
Author Contributions
Investigation, writing—review and editing: A.M.C. and A.S.A. All authors have read and agreed to the published version of the manuscript.
Funding
This work was partially financially supported by the Research and Development Office of Universidad EIA.
Data Availability Statement
The original contributions presented in this study are included in the article. Further inquiries can be directed to the corresponding author.
Conflicts of Interest
The authors declare no conflicts of interest.
Appendix A. Low-Dimensional Realizations of Γ0(n)
Each cube below represents one copy of the base family . For , each layer is indexed by a subset , and every label in that layer is obtained by multiplying the corresponding base label by the monomial . In this way, the diagrams visualize the Boolean-layer decomposition of the support-defined vertex set described in Section 8.
Appendix A.1. The Case GRASS(3)
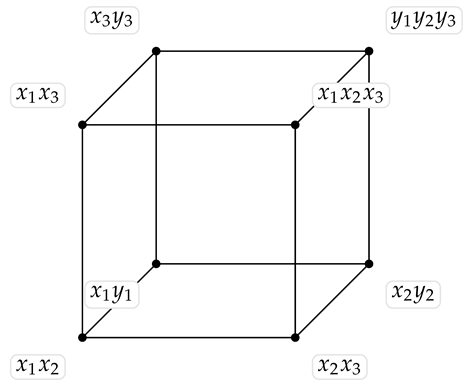
Appendix A.2. The Case GRASS(4)
For , the set of layers is indexed by the subsets of . Hence, consists of two copies of the base family : one corresponding to the original layer , and a second one obtained by multiplying every base label by . In this way, the case provides the first nontrivial illustration of the inductive doubling process: the cube associated with is replicated along the new coordinate direction determined by .
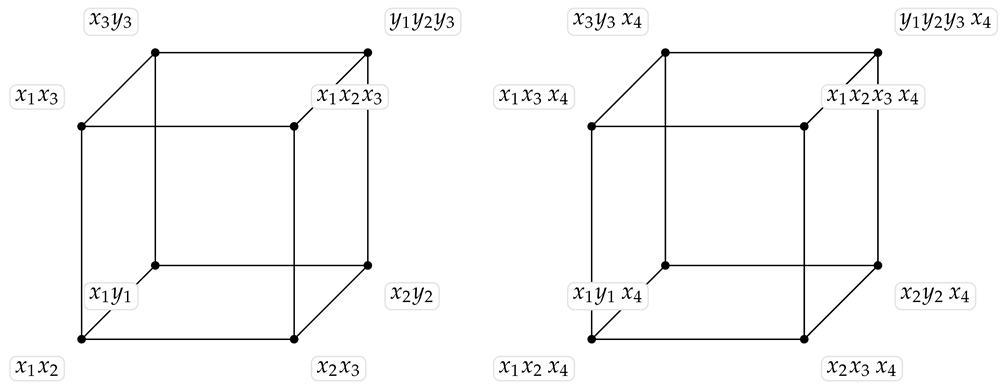
Appendix A.3. The Case GRASS(5)
In this case, the layers are indexed by the subsets of , so the vertex set is visualized as four copies of , arranged according to the Boolean square.
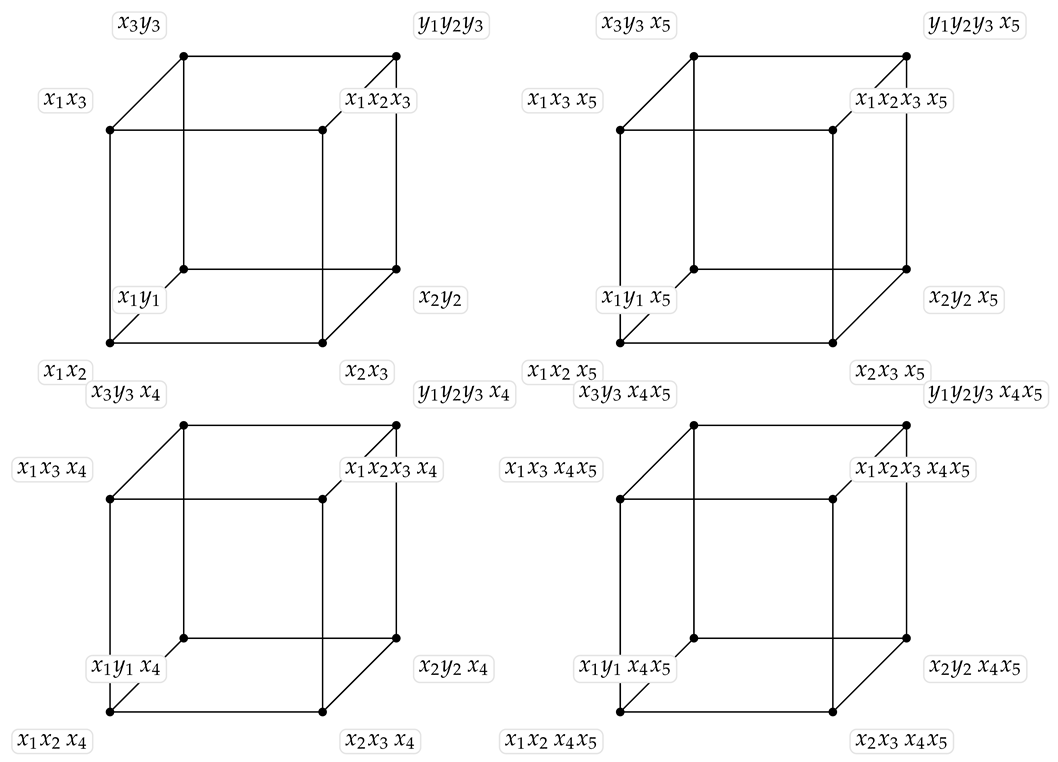
Appendix A.4. A Complete Worked Example for GRASS(4)
We now treat the case in full detail, in order to illustrate explicitly all the structures introduced in the paper: the support map, the polygon family, the Boolean support quiver, the standard Brauer configuration, the standard Brauer quiver, and the numerical invariants appearing in Section 9.
- The vertex set and the support map
For , the index set is , so
Since
it follows that . The Boolean identification
is given explicitly in Table A1.
Table A1.
Explicit form of the Boolean identification .
- The polygon family
The polygon family is
where
and the support polygons are
Thus
exactly as predicted by the general formulas.
- Local incidence and the standard Brauer configuration
For a vertex with
the incident polygon set is
and the canonical cyclic ordering is
For example,
and
with cyclic order
Hence, the standard Brauer configuration is
with the multiplicity function
and valency function
- The Boolean support quiver
Under the Boolean identification , the support quiver is the directed Hasse diagram of , that is, the oriented 4-dimensional hypercube. It has
vertices, distributed in the Hamming layers
and
directed edges. It is loop-free.
- The standard Brauer quiver
The standard Brauer quiver has vertex set
By Theorem 2, its arrows are given explicitly in Table A2.
Table A2.
Arrow multiplicities in the standard Brauer quiver .
In particular, and are visibly different: the first has 16 vertices and encodes Boolean coverings, while the second has only 5 vertices and encodes cyclic successor relations among polygons.
- Layer data, weights, and entropies
Table A3.
Layer-by-layer support data for .
Hence
which agrees with the general formula
The layer entropy is therefore
At the vertex level, the individual weights are
so
The exact entropy decomposition becomes
Since
this gives
that is,
Numerically,
exactly as predicted.
- Global algebraic invariants
The multiplicity sum is
since there is one vertex of multiplicity 2 and the remaining 15 vertices have multiplicity 1. Also,
Hence, the center formula yields
in agreement with the general formula
For the total algebra dimension, the contribution of each Hamming layer to
is
Therefore
Since , Formula (4) gives
Again this agrees with the general formula
since
- Conclusions
The case provides a complete worked example of the whole theory. In this dimension one can see explicitly:
- The Boolean identification ;
- The support-defined polygon family;
- The difference between the Boolean support quiver and the standard Brauer quiver ;
- The layer-by-layer weight distribution;
- The distinction between vertex entropy and layer entropy;
- The exact verification of the formulas for , , and .
- Thus, serves as a concrete numerical and combinatorial model of the general results proved in the paper.
References
- Bott, R.; Tu, L.W. Differential Forms in Algebraic Topology; Graduate Texts in Mathematics; Springer: New York, NY, USA, 1982; Volume 82. [Google Scholar] [CrossRef] [Scilit]
- Bourbaki, N. Algebra I: Chapters 1–3; Springer: Berlin/Heidelberg, Germany, 1989. [Google Scholar] [CrossRef] [Scilit]
- Lang, S. Algebra, 3rd ed.; Springer: Berlin/Heidelberg, Germany, 2002. [Google Scholar] [CrossRef] [Scilit]
- Deligne, P.; Morgan, J. Notes on Supersymmetry. In Quantum Fields and Strings: A Course for Mathematicians; American Mathematical Society: Providence, RI, USA, 1999; Volume 1. [Google Scholar] [CrossRef] [Scilit]
- Kac, V.G. Lie superalgebras. Adv. Math. 1977, 26, 8–96. [Google Scholar] [CrossRef] [Scilit]
- de Araújo Guimarães, A.; Koshlukov, P. Automorphisms and superalgebra structures on the Grassmann algebra. J. Pure Appl. Algebra 2023, 227, 107166. [Google Scholar] [CrossRef] [Scilit]
- Bollobás, B. Modern Graph Theory; Springer: Berlin/Heidelberg, Germany, 1998. [Google Scholar] [CrossRef] [Scilit]
- O’Donnell, R. Analysis of Boolean Functions; Cambridge University Press: Cambridge, UK, 2014. [Google Scholar] [CrossRef] [Scilit]
- Stanley, R.P. Enumerative Combinatorics, Volume 1, 2nd ed.; Cambridge University Press: Cambridge, UK, 2012. [Google Scholar] [CrossRef] [Scilit]
- Brouwer, A.E.; Cohen, A.M.; Neumaier, A. Distance-Regular Graphs; Springer: Berlin/Heidelberg, Germany, 1989. [Google Scholar] [CrossRef] [Scilit]
- Go, J.T. The Terwilliger algebra of the hypercube. Eur. J. Comb. 2002, 23, 399–429. [Google Scholar] [CrossRef] [Scilit]
- Nielsen, M.A.; Chuang, I.L. Quantum Computation and Quantum Information, 10th Anniversary ed.; Cambridge University Press: Cambridge, UK, 2010. [Google Scholar] [CrossRef] [Scilit]
- Horodecki, R.; Horodecki, P.; Horodecki, M.; Horodecki, K. Quantum entanglement. Rev. Mod. Phys. 2009, 81, 865–942. [Google Scholar] [CrossRef] [Scilit]
- Dür, W.; Vidal, G.; Cirac, J.I. Three qubits can be entangled in two inequivalent ways. Phys. Rev. A 2000, 62, 062314. [Google Scholar] [CrossRef] [Scilit]
- Greenberger, D.M.; Horne, M.A.; Zeilinger, A. Going beyond Bell’s theorem. In Bell’s Theorem, Quantum Theory and Conceptions of the Universe; Kafatos, M., Ed.; Kluwer: Alphen aan den Rijn, The Netherlands, 1989. [Google Scholar] [CrossRef] [Scilit]
- Green, E.L.; Schroll, S. Brauer configuration algebras: A generalization of Brauer graph algebras. Bull. Lond. Math. Soc. 2018, 50, 530–544. [Google Scholar] [CrossRef] [Scilit]
- Green, E.L.; Schroll, S.; Snashall, N. Brauer configuration algebras. J. Algebra 2016, 446, 479–508. [Google Scholar] [CrossRef] [Scilit]
- Marsh, R.J.; Schroll, S. The geometry of Brauer graph algebras and cluster mutations. J. Algebra 2014, 419, 141–166. [Google Scholar] [CrossRef] [Scilit]
- Schroll, S. Brauer graph algebras. arXiv 2016, arXiv:1612.00061. [Google Scholar] [CrossRef] [Scilit]
- Erdmann, K.; Skowroński, A. From Brauer graph algebras to biserial weighted surface algebras. J. Algebr. Comb. 2020, 51, 51–88. [Google Scholar] [CrossRef] [Scilit]
- Sierra, A.V. The dimension of the center of a Brauer configuration algebra. J. Algebra 2018, 509, 287–311. [Google Scholar] [CrossRef] [Scilit]
- Agudelo Muñetón, N.; Cañadas, A.M.; Fernández Espinosa, P.F.; Marín Gaviria, I.D. {0, 1}-Brauer configuration algebras and their applications in the graph energy theory. Mathematics 2021, 9, 3042. [Google Scholar] [CrossRef] [Scilit]
- Cañadas, A.M.; Gutierrez, I.; Mendez, O.M. Brauer Analysis of Some Cayley and Nilpotent Graphs and Its Application in Quantum Entanglement Theory. Symmetry 2024, 16, 570. [Google Scholar] [CrossRef] [Scilit]
- Cañadas, A.M.; Bravo Rios, G.; Marín Gaviria, I.D. Brauer Configuration Algebras Arising from Dyck Paths. Mathematics 2022, 10, 1378. [Google Scholar] [CrossRef] [Scilit]
- Cañadas, A.M.; Fernández Espinosa, P.F.; Agudelo Muñetón, N. Brauer configuration algebras defined by snake graphs and Kronecker modules. Electron. Res. Arch. 2022, 30, 3087–3110. [Google Scholar] [CrossRef] [Scilit]
- Cañadas, A.M.; Rodríguez-Nieto, J.G.; Salazar Díaz, O.P. Brauer Configuration Algebras Induced by Integer Partitions and Their Applications in the Theory of Branched Coverings. Mathematics 2024, 12, 3626. [Google Scholar] [CrossRef] [Scilit]
- Sugishita, S. Target space entanglement in quantum mechanics of fermions and matrices. J. High Energy Phys. 2021, 8, 046. [Google Scholar] [CrossRef] [Scilit]
Disclaimer/Publisher’s Note: The statements, opinions and data contained in all publications are solely those of the individual author(s) and contributor(s) and not of MDPI and/or the editor(s). MDPI and/or the editor(s) disclaim responsibility for any injury to people or property resulting from any ideas, methods, instructions or products referred to in the content. |
© 2026 by the authors. Licensee MDPI, Basel, Switzerland. This article is an open access article distributed under the terms and conditions of the Creative Commons Attribution (CC BY) license.