1. Introduction
The burgeoning global population has escalated food demand, exerting considerable pressure on agricultural systems to enhance production efficiency [
1]. In South Africa, this demand strains resources and infrastructure, impacting water reservoirs crucial for agriculture, which use up to 70% of available resources [
2]. Concurrent demands from agricultural, industrial, and domestic sectors further stress finite water supplies [
3]. Regrettably, the compounding effects of climate change exacerbate this issue by altering precipitation patterns and increasing the frequency of extreme weather events. At the same time, rising temperatures heighten evapotranspiration (ET), reducing soil moisture [
4].
These challenges threaten crop yields, undermining efforts to eradicate hunger and malnutrition by 2030, a goal further complicated by the COVID-19 pandemic [
5]. As these issues are expected to worsen, the effectiveness of agricultural systems is increasingly at risk [
6]. Subsequently, there is an urgent need to improve the sustainability and productivity of systems that struggle to meet food demands [
7]. This need is particularly evident in smallholder farms, which, despite their modest scale (typically less than 2 ha), form the backbone of agricultural production systems [
1,
8].
Smallholder farms are crucial for achieving food security objectives by enhancing agricultural productivity and promoting socio-economic advancement, particularly in developing regions [
1,
9]. However, climatic variability and limited resources hinder productivity [
8,
10]. The sugarcane industry is vital to South Africa’s agricultural sector, providing employment and promoting rural development [
11,
12]. Many small-scale farmers depend on rainfed agriculture, making them vulnerable to reduced rainfall and extreme weather [
13]. Thus, innovative strategies to enhance resilience are critical [
14].
Furthermore, erratic precipitation may increase reliance on irrigation to sustain agricultural yields in forthcoming years [
15,
16]. Consequently, efficient and environmentally sound irrigation techniques are vital for adapting to changing climates. Moreover, precise estimates of crop water needs are essential for managing irrigation systems [
17]. A significant portion of crop water use results from ET, which includes water released through soil evaporation and plant transpiration [
2,
18]. Consequently, accurate ET estimates are essential for rigorous water management [
19]. Various in situ methodologies have been devised and implemented to ascertain ET levels with precision [
20].
Micrometeorological methods are among the most extensively employed for estimating actual ET (ET
a) [
21]. These approaches utilise atmospheric observations to accurately estimate water vapour flux. The eddy covariance (EC) technique is the gold standard for in situ ET measurements, as it provides real-time latent heat flux (LE) data. However, the applicability of these techniques in smallholder farming is limited by the need for sophisticated equipment and trained personnel [
22]. Consequently, remote sensing (RS) methodologies present viable alternatives, potentially offering extensive data coverage across large geographical areas, including remote regions, at lower costs [
23,
24].
RS includes three primary technologies, satellite earth observation (SEO), manned aerial vehicles, and unmanned aerial vehicles (UAVs), each providing unique advantages for agricultural monitoring [
25]. SEO utilises earth-orbiting satellites to capture data across multiple spectral bands, enabling assessments of crop health, land-cover changes, and soil conditions over extensive areas [
24]. However, fragmentation and diversity in smallholder farming systems hinder the effective use of freely available SEO datasets, which are constrained by spatial, spectral, and temporal limitations [
8]. Therefore, alternative and bespoke methodologies are necessary, as the financial implications of advanced systems render them impractical for many farming communities [
26].
UAVs offer significant advantages in precision agriculture (PA), acting as cost-effective tools that provide spatially representative data at user-defined intervals, which can enhance agricultural productivity [
8,
27]. Additionally, integrating Very High-Resolution (VHR) cameras on UAVs enhances crop analytics by overcoming limitations associated with satellite imagery [
28,
29]. However, extracting insights from UAV data can be challenging due to the computational demands of processing, requiring specialised software and expertise that may not be readily available [
22]. Addressing these issues is crucial for successfully integrating UAVs in smallholder agriculture.
Two primary approaches are commonly used to estimate ET
a from UAV data: thermal-based surface energy balance models and empirical vegetation index (VI)-based methods [
30]. Recent advances in ET estimation have increasingly incorporated thermal infrared imagery, data fusion techniques, and deep learning frameworks to improve retrieval accuracy and model generalisation across agricultural environments [
30,
31]. However, these approaches often require specialised sensors, extensive calibration procedures, and computationally intensive processing workflows, which may limit their practical implementation in smallholder farming systems. Although thermal-based approaches can estimate LE, they were excluded from this study due to their higher cost, greater technical complexity, and limited applicability in resource-constrained agricultural environments. In contrast, VI-based approaches offer a more scalable alternative owing to their lower technical demands, compatibility with multispectral UAV imagery, and suitability for field-scale implementation within smallholder systems. Unlike conventional meteorological stations, which provide point-based estimates of atmospheric demand, UAV-derived ET–VI approaches enable spatially explicit assessment of crop condition and canopy variability, thereby supporting improved characterisation of field-scale water use under smallholder conditions.
VI models use the relationship between the crop coefficient (K
c) and reference ET (ET
0) to forecast crop water needs [
32]. The ET–VI method employs VIs as proxies for K
c, following the framework outlined in the Food and Agriculture Organisation (FAO) methodology [
33]. Similar VI-based ET formulations have been applied across agricultural systems using multispectral observations and cloud-based processing environments, demonstrating their utility as computationally accessible alternatives to more data-intensive ET retrieval approaches [
34,
35]. This method applies the Penman–Monteith equation [
36] to calculate ET
0, which is subsequently adjusted by K
c to estimate potential ET (ET
p) under ideal conditions [
34]. ET
p is further adjusted using the stress coefficient (K
s) to account for water deficits, resulting in ET
a [
34].
The K
s delineates the reduction in ET
a attributed to the water deficit [
33]. Under conditions of sufficient irrigation, the K
s is conventionally assigned a value of 1 [
33]. Correspondingly, a VI approximates the combined impact of K
c and the K
s within the ET-VI methodology [
33]. The FAO Irrigation and Drainage Paper No. 56 (FAO56) framework encompasses two distinct methodologies for determining K
c: the single K
c method, which integrates crop transpiration and soil evaporation into a unified coefficient, and the dual K
c method, which treats crop transpiration and soil evaporation as separate components [
36]. However, the single K
c approach predominates in the literature [
34,
35].
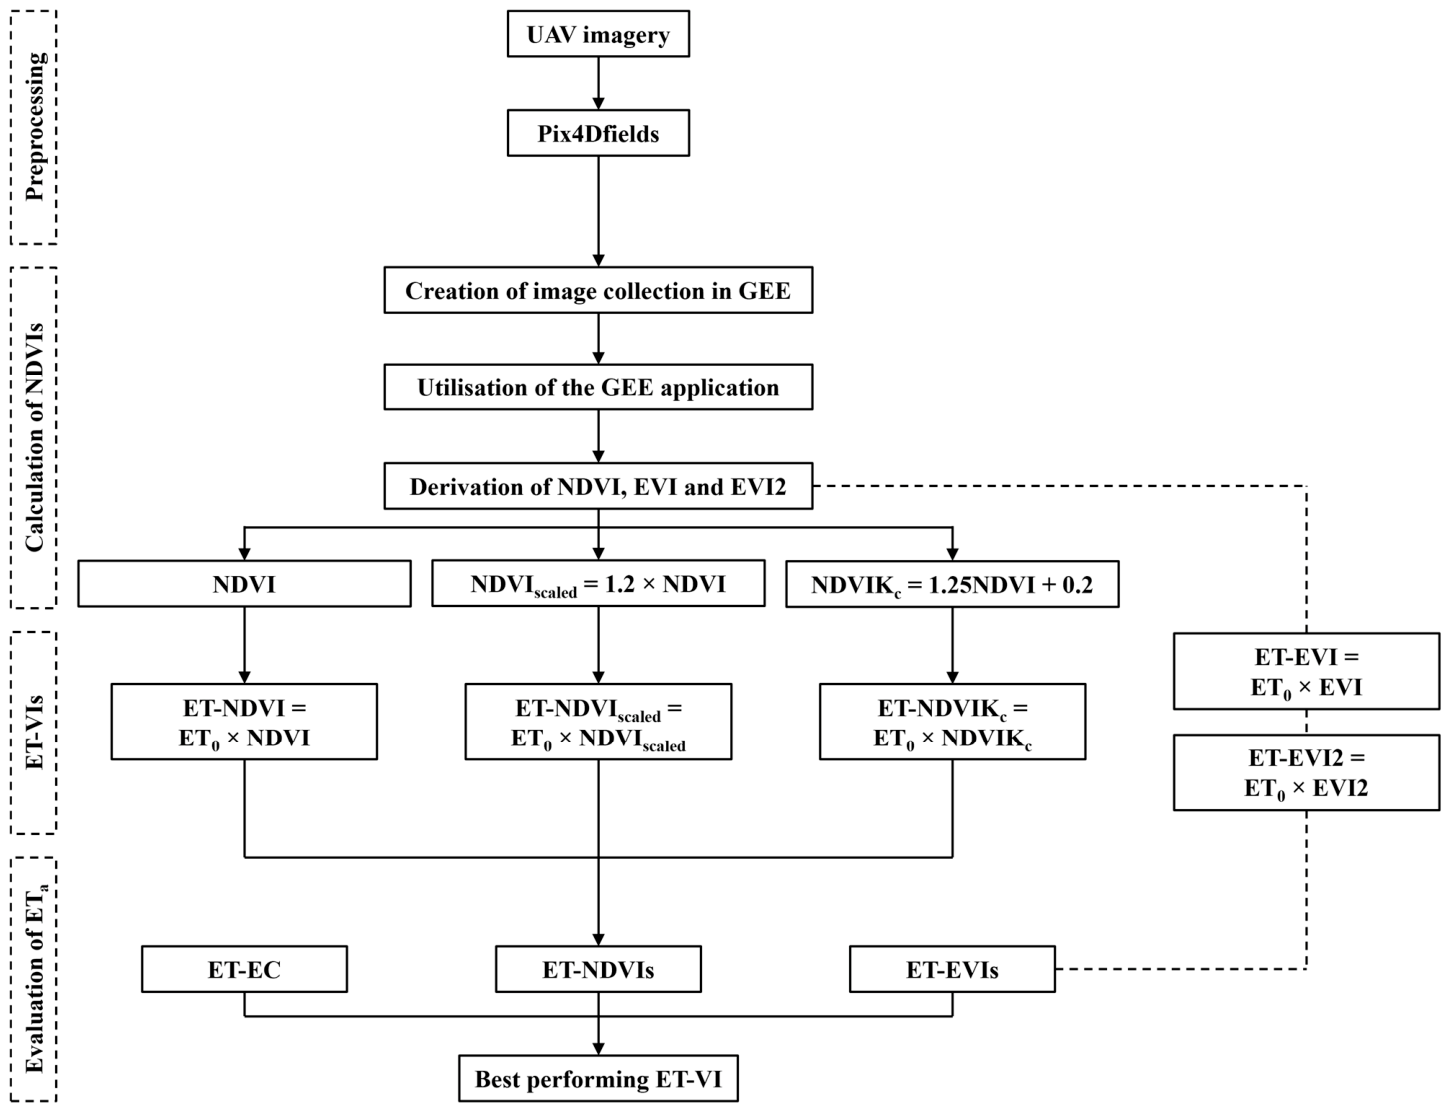
Frequently utilised VIs include the Normalised Difference Vegetation Index (NDVI), the Enhanced Vegetation Index (EVI), and the two-band variant of the EVI (EVI2) [
35,
37]. These indices have undergone extensive evaluation to estimate ET
a across diverse landscapes [
38,
39,
40,
41,
42]. Among these VIs, NDVI has gained significant traction as a surrogate for K
c at the field level across various crop types [
33]. Advances in UAV technology have further enhanced this research, enabling precise analysis of NDVI–K
c dynamics and demonstrating the potential of UAVs for effective water management [
32,
37,
43].
Given the limited affordability and scalability of in situ and thermal-based ET methods in smallholder systems, there remains a need for ET estimation frameworks that balance predictive capability with operational feasibility. This study, therefore, investigates a cost-effective and replicable approach for estimating ET
a using UAV-derived multispectral imagery integrated with machine learning (ML) to strengthen NDVI–K
c modelling. Unlike conventional VI-based approaches that predominantly rely on linear relationships [
44,
45,
46], the proposed framework adopts a more flexible modelling strategy and systematically evaluates five ET–VI approaches—NDVI, scaled NDVI (NDVI
scaled), K
c-adjusted NDVI (NDVIK
c), EVI, and EVI2. In doing so, the study seeks to strengthen practical ET monitoring within smallholder agriculture while extending methodologies that have received limited evaluation in existing literature [
34,
47].
Furthermore, despite growing interest in UAV-based ET estimation, relatively few studies have evaluated operationally scalable ET–VI approaches within heterogeneous rainfed smallholder systems, where financial, computational, and technical constraints often limit the applicability of thermally driven surface energy balance models [
19,
30]. Moreover, ML remains underexplored for improving NDVI–K
c relationships within UAV-based ET frameworks under data-scarce conditions [
48]. This study addresses these gaps by comparing five UAV-derived ET–VI approaches integrated with ML, emphasising methodological accessibility and field-scale applicability in smallholder sugarcane systems.
Accordingly, this study is guided by three primary objectives: first, to develop an ML model that correlates in situ Kc measurements with NDVI to improve the estimation of ETa; second, to evaluate RS-derived ET–VI approaches by systematically comparing NDVI, NDVIscaled, NDVIKc, EVI, and EVI2 against EC-measured ETa; and third, to identify the most suitable UAV-based ET–VI method for application in smallholder agricultural systems.
3. Results
3.1. Assessment of In Situ Data Quality
The average air temperature within the sugarcane field ranged from 7.3 to 27.9 °C. The mean wind velocity was recorded at 2.0 m s−1, while the saturated vapour pressure was measured at 2.19 kPa. RH exhibited notable seasonal variation, with higher RH values observed during the summer months, ranging from 69% to 99%, and lower RH values during the winter months, ranging from 38% to 96%. The mean Rn and G measurements yielded 6.75 MJ m−2 and 0.35 MJ m−2, respectively. Cumulative precipitation over the 10-month measurement period totalled 1228 mm, with seasonal variability. The summer months recorded higher precipitation, peaking at 331 mm in December, compared to a maximum monthly accumulation of 11 mm in July during winter.
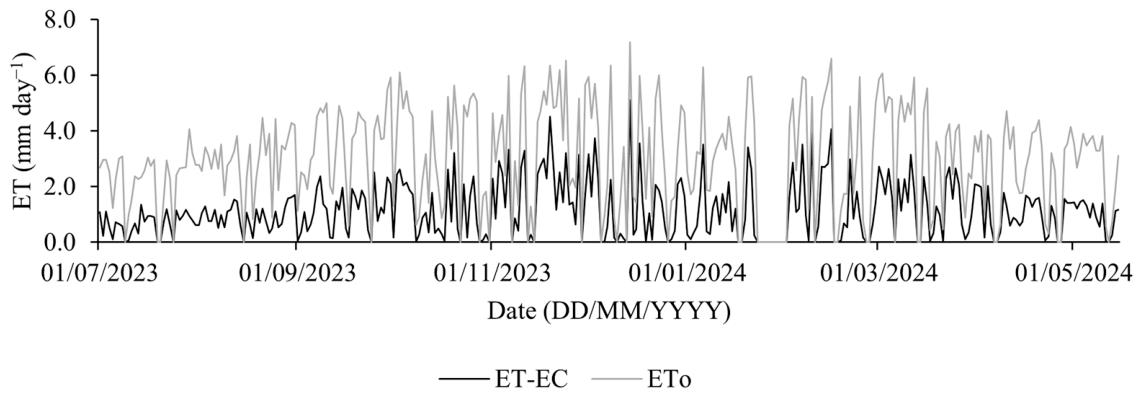
The series analysis reveals a pronounced seasonal trend in ET
0 and EC system-derived ET (ET
EC) (
Figure 7). ET
0 consistently surpasses ET
EC across the observation period, with both metrics exhibiting evident seasonal variations. Daily values reach their lowest in June, peak in December, and gradually decrease through May. This cyclical pattern is consistent with expected seasonal climate changes, where warmer temperatures, increased rainfall, and higher solar radiation during summer promote elevated ET rates. At the same time, cooler and drier winter conditions suppress them. The persistent difference between ET
0 and ET
EC, with ET
0 consistently higher, corresponds to a K
c ranging from 0.39 to 0.52 over the monitoring period.
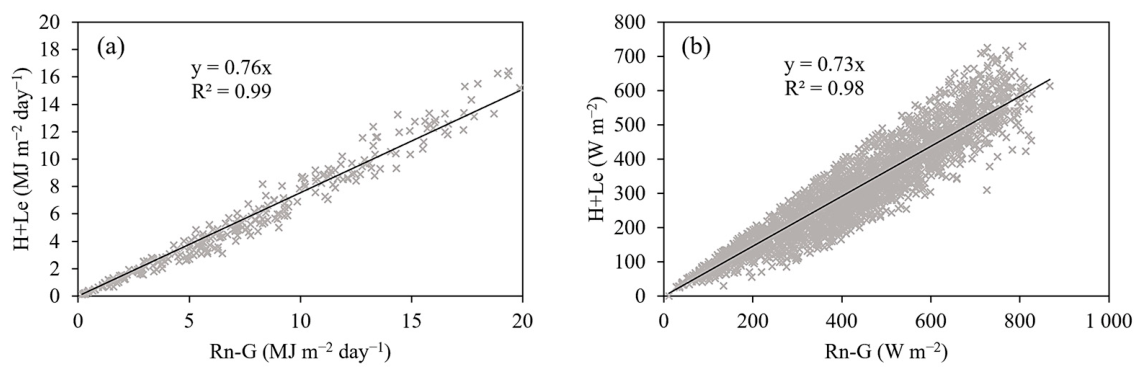
The precision of the EC system in quantifying turbulent fluxes was assessed through energy balance closure (EBC) analysis. EBC involves a linear regression (LR) between turbulent energy fluxes (H + LE) and available energy (Rn-G) [
75,
76]. Jin et al. (2022) state that perfect EBC requires the slope of the regression line to equal one and the intercept to be zero [
77]. Accordingly, the analyses constrained the intercept to zero [
77]. The findings revealed that turbulent fluxes were approximately 27% and 24% lower than available energy for the 30-min and daily intervals, respectively (
Figure 8). These results indicate satisfactory EBC, consistent with previous studies reporting deficits ranging from 10% to 30% [
75,
76,
78,
79]. Additionally, R
2 values were 0.98 for the 30-min timestep and 0.99 for the daily timestep, further supporting the reliability of the measurements.
3.2. Comparative Analysis of ETEC and Kc Model Predictions
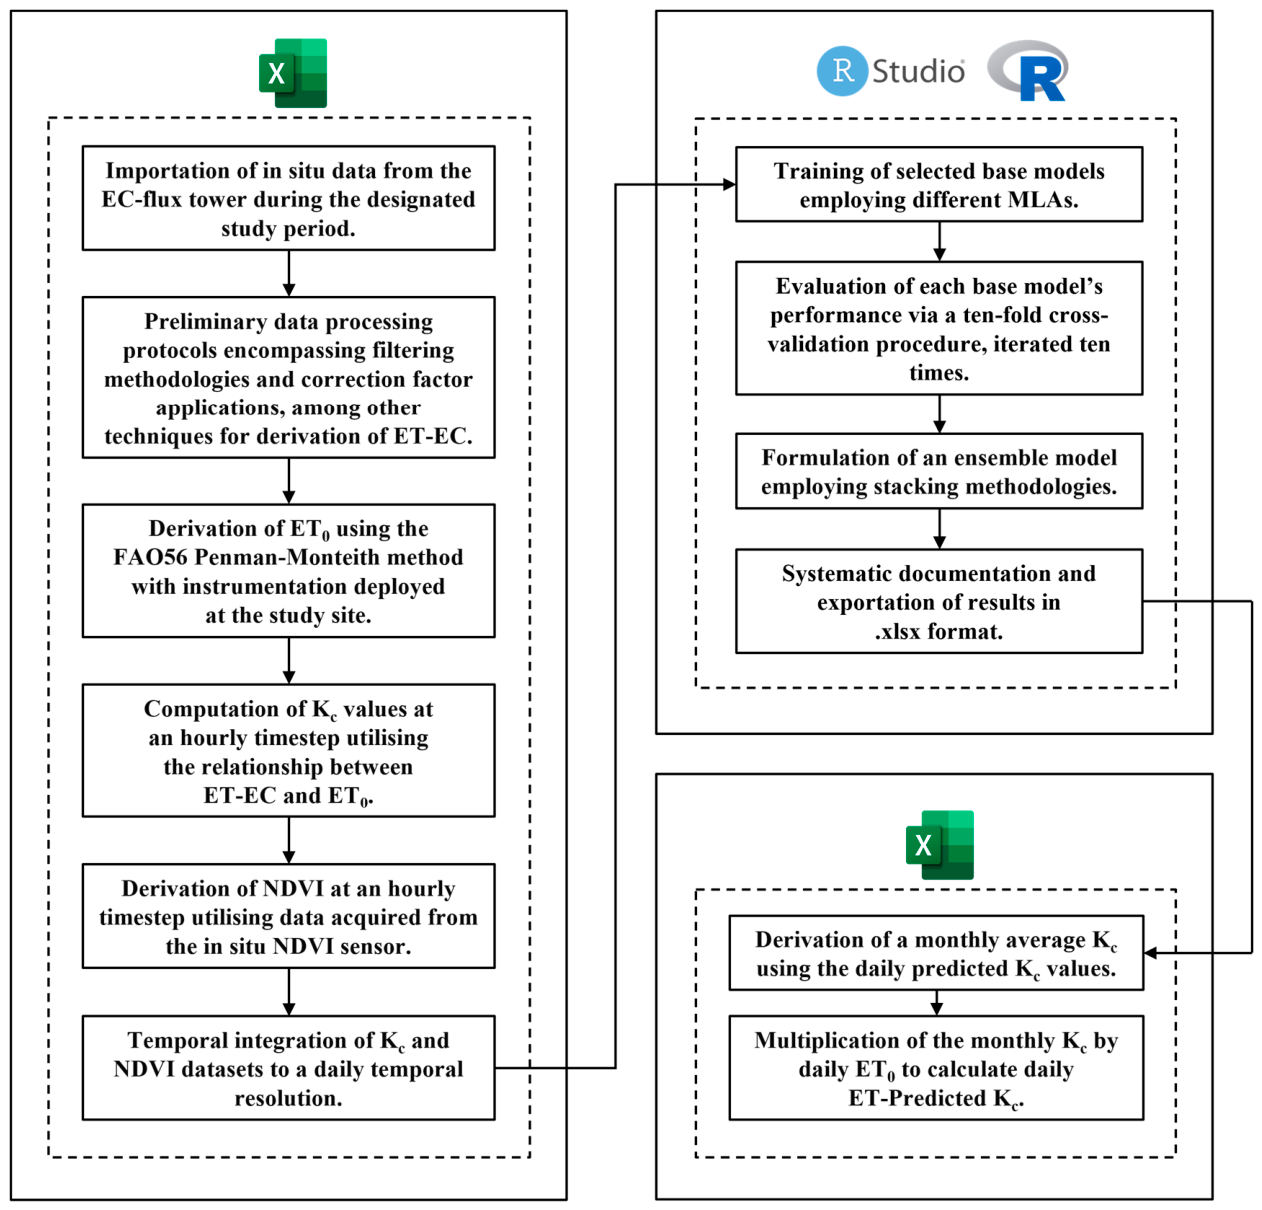
The ensemble model, utilising the RF algorithm as the meta-model—that is, the model used to combine the outputs of the individual base models (e.g., GLM, kNN, SVMRadial)—produced the strongest performance among the evaluated modelling approaches within the available dataset. The model yielded an RMSE of 0.11, an R2 of 0.68, and an MAE of 0.07. These metrics indicate that the ensemble approach captured a substantial proportion of the variability in the observed Kc values while maintaining relatively low prediction errors within the available dataset. However, because model evaluation was conducted using repeated randomised cross-validation, these performance metrics should be interpreted within the context of the adopted validation framework and should not be regarded as evidence of temporal predictive transferability.
The monthly observed K
c values varied from 0.48 to 0.80 (
Table 4). The highest observed K
c of 0.80 was recorded in February, indicating elevated water use. Conversely, observed K
c values declined to 0.48 by May, reflecting reduced water use as the growing season progressed. Predicted K
c values ranged from 0.56 to 0.62, with the highest in February. The lower variability of predicted K
c compared to observed values suggests that the model tends to moderately underestimate higher K
c values and slightly overestimate lower ones. This pattern indicates that the model provides a relatively conservative estimate of water use, particularly under peak crop water demand conditions. Notably, in March, the predicted K
c closely matched the observed value (0.57 predicted vs. 0.58 observed), and the lowest predicted K
c of 0.56 aligned well with observed K
c values in April and May.
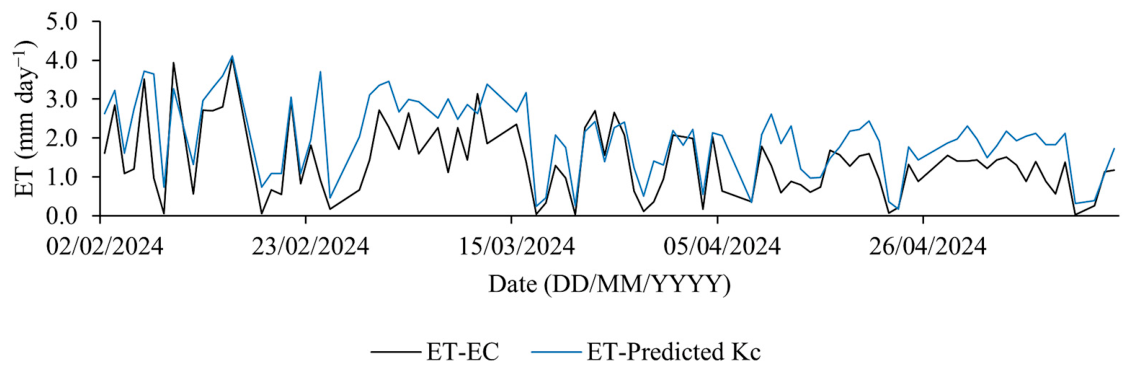
The temporal distribution of observed and predicted ET
a values reveals a consistent over-simulation by the prediction model throughout the data collection period (
Figure 9). Descriptive statistics highlight this trend, with the mean predicted ET
a at 1.99 mm day
−1 compared to the observed mean of 1.40 mm day
−1. The median predicted ET
a of 2.05 mm day
−1 also exceeds the observed median of 1.32 mm day
−1, indicating a persistent bias in the model’s ET
a estimates. Variability around the mean is comparable between datasets, with predicted ET
a values displaying a slightly higher standard deviation (0.94) than observed values (0.91). However, the cumulative effect of this overestimation is evident, with the total predicted ET
a reaching 181.35 mm, significantly surpassing the total observed ET
a of 127.12 mm over the study period.
The percentile analysis (95% confidence interval (CI)) corroborates these findings, indicating overestimation across all percentiles and suggesting a systematic bias in the prediction algorithm (
Table 5).
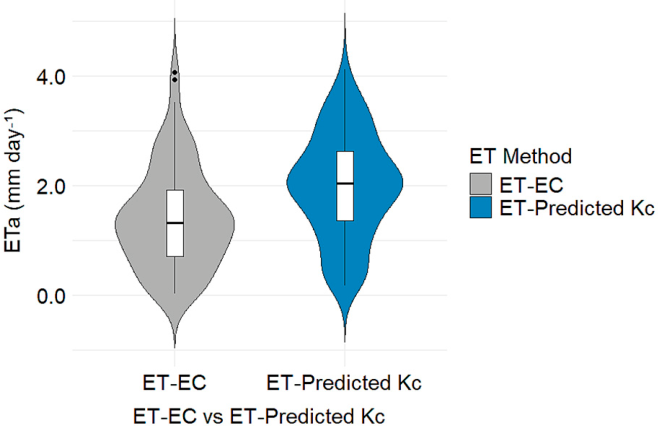
Figure 10 presents a visual summary using violin plots, which show a generally higher distribution of predicted ET
a values with a notable upward skew, aligning with the trends observed in the descriptive statistics and percentile analysis. These results highlight the model’s tendency to overestimate ET
a and the need for model adjustments to align closely with observed data.
The regression analysis between ETPredicted Kc and ETEC yielded an R2 of 0.61, indicating that the model explains 61% of the variability in observed ETEC, suggesting moderate predictive strength. However, the RMSE of 0.86 mm day−1 and MAE of 0.66 mm day−1 further highlight the model’s average deviations from observed values, indicating room for improvement in predictive precision.
The Shapiro–Wilk test assessed the normality of the ETEC and ETPredicted Kc datasets. The results indicated that the observed ETEC values deviated significantly from a normal distribution (W = 0.958, p = 0.005), whereas the predicted ETKc values did not deviate significantly (W = 0.979, p = 0.151). Given the non-normality of the observed data, non-parametric tests were deemed appropriate for trend and correlation analysis, justifying the use of the Mann–Kendall (MK) test and Spearman’s correlation.
The MK test yielded a tau (τ) of 0.607 (p < 2.22 × 10⁻¹⁶), indicating a positive trend in ETPredicted Kc relative to ETEC, thus supporting the model’s reliability in capturing temporal trends. Spearman’s correlation further confirmed this relationship, with a rho (ρ) of 0.783 (p < 2.22 × 10⁻¹⁶), demonstrating a strong positive correlation between ETPredicted Kc and ETEC. These results show that the model’s predictions closely track variations in observed ETEC values, confirming its accuracy in reflecting observed trends.
3.3. Comparative Analysis of ET-VI Products Against EC Measurements
To assess the accuracy of the ET-VI products, ET-VI estimates were juxtaposed with reported ET
EC values (see
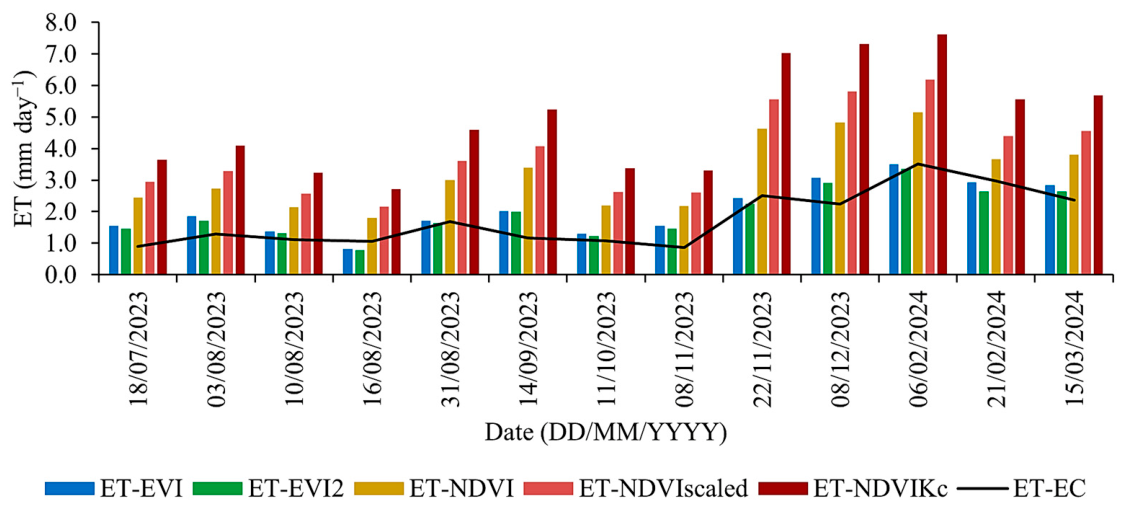
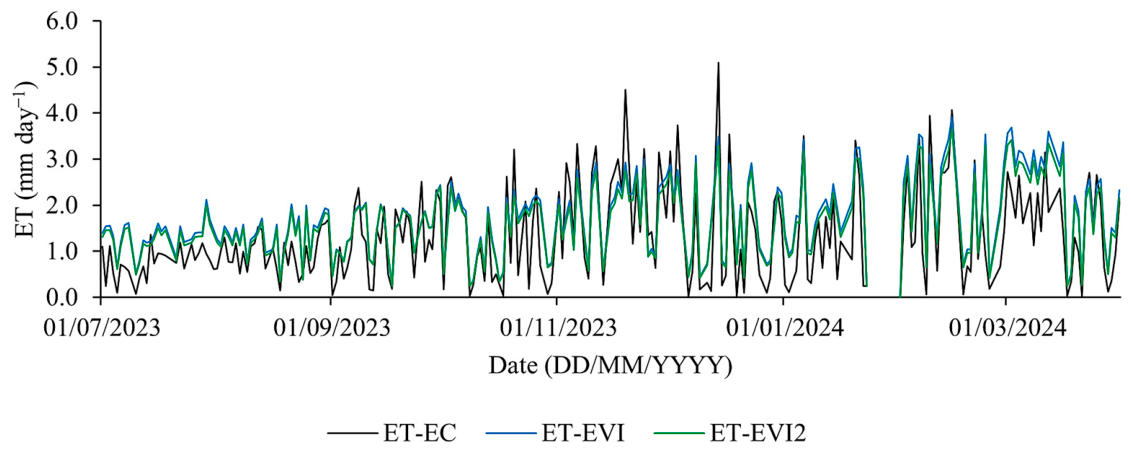
Figure 11 and
Figure 12). The findings reveal that all ET-VIs surpassed the ET
EC values, with ET
EVI2 demonstrating the closest approximation to ET
EC. Notably, ET
NDVIKc exhibited the largest deviation from ET
EC, with a difference of 639 mm. Conversely, ET
EVI2 exhibited the smallest deviation from the reported ET
EC value (71 mm), followed by ET
EVI, ET
NDVI, and ET
NDVIscaled (94 mm, 441 mm, and 315 mm, respectively). As depicted in
Figure 11, the ET
NDVI estimates bear a closer resemblance to ET
EVI and ET
EVI2 than ET
NDVIscaled and ET
NDVIKc. The lowest and highest ET
a values were attributed to ET
EVI2 and ET
NDVIKc, respectively.
The ET
EC data generally exhibit lower values than ET-VIs across all percentiles (
Table 6). For instance, at the 50th percentile, ET
EC is 1.14 mm day
−1 (95% CI: [1.00, 1.28]), while ET-VIs range from 1.14 to 3.95 mm day
−1, with corresponding 95% CIs of [1.40, 1.78] for the lower end and [3.80, 4.10] for the upper end. Percentile trends indicate a general increase in ET
a values across all variables, reflecting similar distribution patterns. However, ET
EC has a narrower interquartile range (IQR) of 1.49 mm day
−1 compared to the broader IQRs of ET-VIs, suggesting lower variability. At higher percentiles (e.g., 90th and 95th), ET
EC also shows lower values than ET-VIs, indicating potential differences in extreme ET
a values.
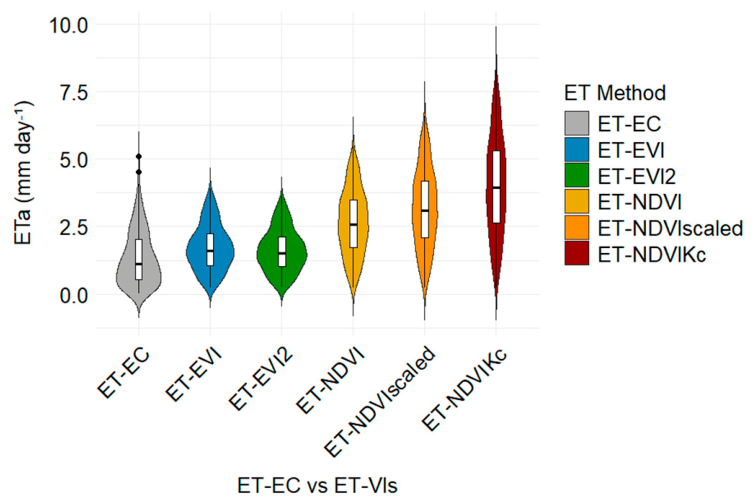
Figure 13’s violin plots reinforce these findings, showing generally higher distributions and an upward skew for ET-VIs relative to ET
EC. The EVI-based methods align more closely with the ET
EC distribution, suggesting greater accuracy in ET
a estimation.
The findings indicate that ET
NDVI, ET
NDVIscaled, and ET
NDVIKc have identical R
2 values (0.67) (
Table 7), indicating that approximately 67% of the observed variability in ET
a can be attributed to these methods. Similarly, ET
EVI and ET
EVI2 show an R
2 of 0.63, accounting for 63% of the variability. This suggests that the NDVI variants have greater explanatory power than the EVI methods. Notably, ET
NDVI, ET
NDVIscaled, and ET
NDVIKc tend to overestimate ET
a, with ET
NDVIKc exhibiting the most pronounced overestimation, followed by ET
NDVI and ET
NDVIscaled. Conversely, ET
EVI and ET
EVI2 tend to under-simulate lower ET
a values and overestimate higher ET
a values.
Regarding error metrics, ETEVI2 shows the lowest RMSE (0.67 mm day−1) and MAE (0.52 mm day−1), indicating minimal discrepancies. ETEVI follows closely, with an RMSE of 0.73 mm day−1 and an MAE of 0.56 mm day−1. In contrast, ETNDVI presents higher RMSE (1.49 mm day−1) and MAE (1.32 mm day−1), while ETNDVIscaled and ETNDVIKc reveal greater discrepancies, with ETNDVIKc exhibiting the highest mean difference (201%), followed by ETNDVIscaled (139%) and ETNDVI (99%). In comparison, ETEVI (30%) and ETEVI2 (22%) show smaller mean differences, reflecting closer alignment with ETEC values.
The Shapiro–Wilk test was conducted to assess the normality of the datasets for ETEC and various VIs. The results indicate that the ETEC dataset significantly deviates from a normal distribution (W = 0.932, p < 0.001). In contrast, while NDVI, NDVIscaled, and NDVIKc exhibit statistics exceeding 0.98, the corresponding p-values (<0.01) still lead to the rejection of the null hypothesis of normality. Similarly, EVI and EVI2 show statistics of 0.976 and 0.979, respectively, with p-values indicating a significant departure from normality. Consequently, the reliance on non-parametric methods, such as the MK test and Spearman’s correlation, is advocated for trend analysis.
The MK test results indicate strong positive associations for NDVI, NDVI
scaled, and NDVI
Kc, all exhibiting τ values of 0.652 and
p-values of 2.22 × 10
−16, indicating statistically significant upward trends (
Table 8). ET
EVI and ET
EVI2 also demonstrate substantial upward trends with τ values of 0.638 and 0.643, respectively, maintaining the same significance level. Spearman’s correlation analysis further corroborates these findings, with correlation coefficients (ρ) for all indices ranging from 0.822 to 0.835, indicating strong positive monotonic relationships with ET
EC. The associated
p-values (<0.001) confirm the statistical significance of these relationships, providing robust evidence against the null hypothesis of no correlation.
3.4. ETa Maps
Spatially explicit ET
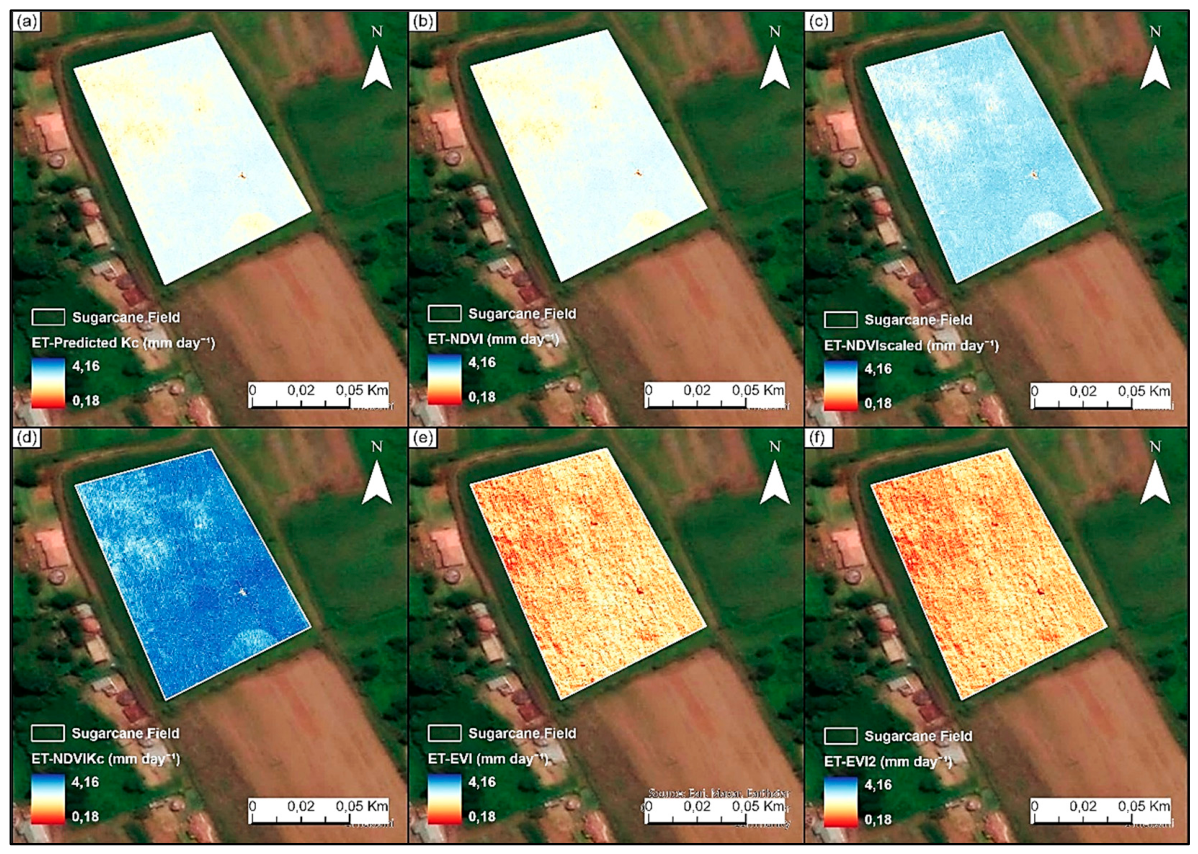
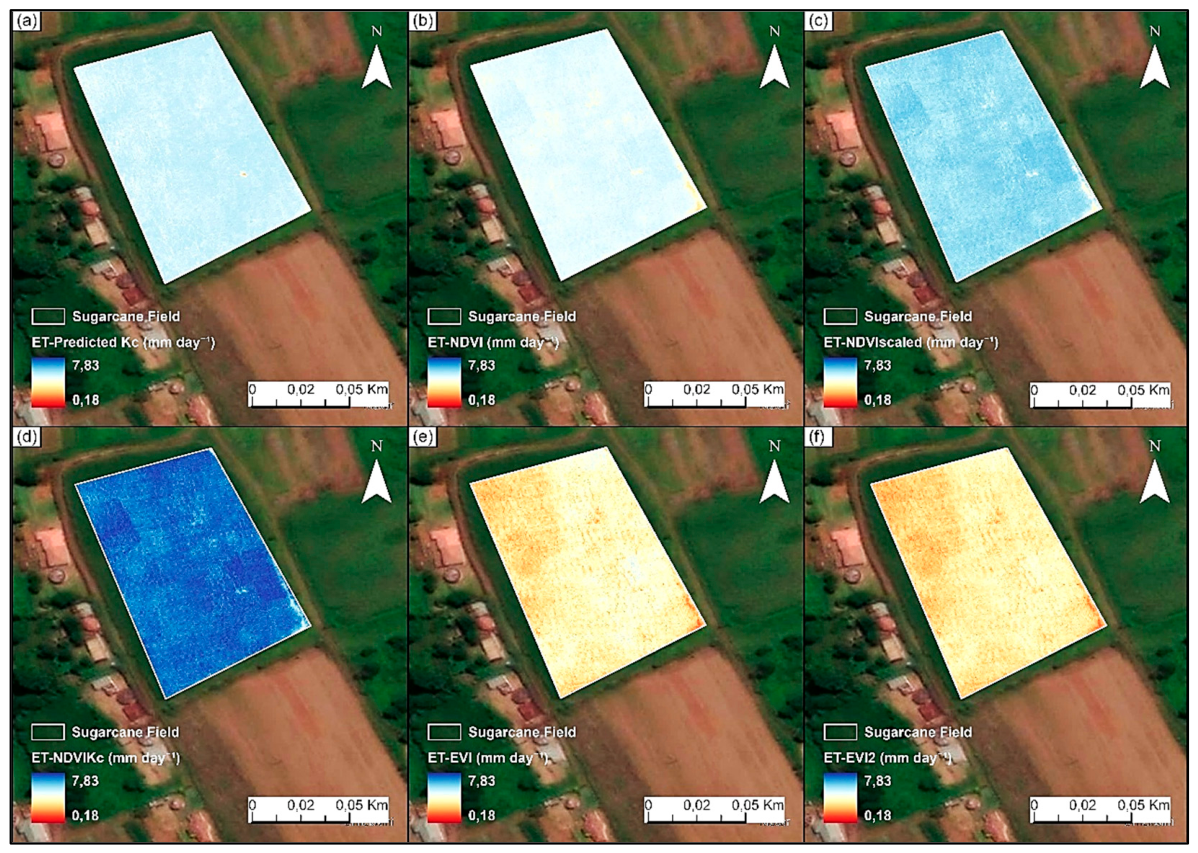
a maps (
Figure 14 and
Figure 15) for the sugarcane cropland were generated for select dates during the cooler and drier winter (18 July 2023) and the warmer and wetter summer (6 February 2024), utilising the ET-VI approaches. For the winter ET
a maps, the mean ET
a ranged from 1.45 mm day
−1 (ET
EVI2 method) to 3.65 mm day
−1 (ET
NDVIKc method). The summer ET
a maps show noticeably higher ET
a values, with mean ET
a values ranging from 3.29 mm day
−1 (ET
EVI2) to 7.21 mm day
−1 (ET
NDVIKc). The standard deviations and minimum ET
a values also increased in the summer, indicating greater variability and a higher baseline ET
a. These findings demonstrate a significant rise in ET
a from winter to summer, corresponding to increased water usage during the warmer season.
4. Discussion
Smallholder farmers increasingly grapple with the challenges posed by climate change, particularly regarding post-harvest losses that threaten food security and health. In this context, UAV-based ETa estimation presents a promising mitigation strategy. Ground truth data were crucial for validating the accuracy and performance of this study’s RS-based VI approaches. The EC system was utilised for this assessment. The following subsection discusses the implementation and performance of the EC system.
4.1. Assessment of In Situ Data Quality
Despite the well-documented challenges associated with achieving complete EBC in EC applications, including footprint variability, atmospheric transport processes, and instrument-related uncertainties, the daily EBC ratio of 76% observed in this study falls within the range commonly reported in the literature. Nevertheless, incomplete closure may contribute to uncertainty in LE estimates and should therefore be considered when interpreting comparisons between EC-derived and remotely sensed ET estimates. Non-closure factors include landscape homogeneity violations, measurement errors, and advection influences [
80]. However, EBC improves with longer time steps, as daily averaging mitigates atmospheric fluctuations [
80].
4.2. Performance Evaluation of Kc Prediction Models Using ML Approaches
A relationship between in situ NDVI and Kc was assessed using LR during a portion of the mature sugarcane growing phase (3 February to 15 May 2024), yielding a low R2 value of 0.04. A sixth-order polynomial regression (PR) also produced a similarly low R2 of 0.11. Consequently, ML techniques, including RF, RPART, GLM, kNN, and SVMRadial, were implemented to better capture this complex relationship. While individual ML algorithms exhibited poor performance metrics for R2, RMSE, and MAE, the RF ensemble model demonstrated predictive capacity with an R2 of 0.68, an RMSE of 0.11, and an MAE of 0.07.
The initial weak association observed with the LR and PR models can be attributed to the data being captured solely in the late season of sugarcane cultivation. As Hunsaker et al. (2003) noted, NDVI values exceeding 0.8 may deviate from linearity due to saturation effects, particularly when full vegetative cover is achieved [
38]. This saturation limits NDVI’s sensitivity to variations in crop water stress and K
c. Although polynomial models provide increased flexibility, they may still fall short in representing the non-linear relationships between NDVI and K
c under full canopy cover. Thus, ML techniques are justified, as they can more effectively model these complex interactions.
The RF algorithm recorded the highest R
2 value of 0.19 among the individual ML models. Although its RMSE (0.19) and MAE (0.15) were not optimal compared to other models, the differences were minimal, suggesting that RF Regression (RFR) estimates K
c more accurately than the other algorithms. The subsequent derivation of performance metrics using the RFR ensemble model (R
2 = 0.68, RMSE = 0.11, MAE = 0.07) are consistent with those reported in previous studies. For instance, Shao et al. (2021) found R
2 values ranging from 0.48 to 0.77 and RMSE values between 0.11 and 0.17 when estimating K
c for maize crops using UAV-based VIs and ground-based leaf area index (LAI) with the RFR algorithm [
81].
Additionally, Shao et al. (2023) utilised UAV-based VIs and found that the RFR model achieved the highest accuracy, recording an R
2 value of 0.69 and an RMSE of 0.10 [
82]. Thus, they recommended the RFR model as the preferred method for estimating maize K
c. Similarly, Er-Raki et al. (2013) reported an R
2 value of 0.63 for a K
c estimation model for table grapes based on ground-based NDVI [
83]. In contrast, Alam et al. (2018) demonstrated higher precision in K
c estimation for irrigated pasture, achieving an R
2 value of 0.84 at a small scale (<1 m
2) [
84]. These findings indicate that the RFR ensemble approach effectively estimates K
c for rainfed sugarcane, aligning with the performance of prior studies.
4.3. Comparative Analysis of ET-VI Products Against EC Measurements
The VI methodology integrates crop transpiration and soil evaporation into a single K
c value, often estimated using NDVI. While a K
c of 1.2 (NDVI ≈ 0.8) is typical for peak vegetative vigour under minimal water stress and 0.4 (NDVI ≈ 0.16) for early growth stages, the VI methodology primarily accounts for transpiration, potentially underestimating soil evaporation [
35]. Data collection, however, commenced seven months into the growing season. Therefore, this extensive pre-existing vegetation cover mitigated potential K
c underestimation from a lack of early-growth-stage data [
85]. Nevertheless, rainfed cultivation suggests the possibility of water stress if precipitation is insufficient for optimal growth, potentially leading to an overestimation of the K
c value (1.2) used in empirical relationships, especially considering available in situ K
c data derived from instrumentation on the meteorological flux tower.
Acknowledging these considerations, the study evaluated three NDVI-based ET
a models (ET
NDVI, ET
NDVIscaled, and ET
NDVIKc) and two EVI-based models (ET
EVI and ET
EVI2) against ET
EC over a nine-month period (July 2023–March 2024). Across all VI-based approaches, estimated ET
a values were generally higher than ET
EC. However, the EVI-based models (ET
EVI and ET
EVI2) demonstrated superior performance, which may be attributable to their reduced sensitivity to canopy saturation and soil background effects [
47].
These findings should be interpreted in the context of uncertainty associated with incomplete EBC, which may affect estimates of LE and, consequently, comparisons between EC-derived and remotely sensed ETa products. As no additional closure correction was applied, the analysis presented here represents an evaluation against measured EC fluxes rather than an absolute measure of ETa. The non-parametric distribution of the data, as determined by the Shapiro–Wilk test, further justified the use of the MK and Spearman rank correlation tests to evaluate monotonic trends and relationships between ET–VIs and ETEC, respectively.
Although ET
EVI and ET
EVI2 displayed similarities to ET
EC, the MK test indicated a stronger association between ET
NDVI and ET
EC. Spearman’s rho showed stronger positive monotonic relationships for ET
NDVI (ρ = 0.835) compared to ET
EVI (ρ = 0.822) and ET
EVI2 (ρ = 0.827). Despite this, ET
EVI2 and ET
EVI exhibited superior RMSE and MAE performance. Conversely, ET
NDVIKc and ET
NDVIscaled displayed poorer performance, highlighting the limitations of NDVI at high biomass, where saturation reduces sensitivity to vegetation changes [
35]. EVI’s inclusion of a blue band and its coefficients mitigates atmospheric and soil background effects, improving its robustness [
86]. Consistent with Woldemariam et al. (2024), EVI-based models outperformed NDVI-based models, emphasising EVI’s superior sensitivity to biophysical changes crucial for monitoring sugarcane growth [
47]. This aligns with previous research highlighting the superiority of EVI and EVI2 in estimating ET
a in semi-arid regions [
35,
87]. These findings underline the ET-VI approach’s potential for sustainable water and resource management in small-scale agriculture.
4.4. Optimal Methods and Considerations for the Smallholder Farmer Context
Among the developed ET-VI products—ETNDVI, ETNDVIscaled, ETNDVIKc, ETEVI, and ETEVI2—the ETEVI2 method emerged as the most reliable based on comprehensive performance metrics and statistical analyses. A subsequent comparison between the ETEVI2 dataset and ETPredicted Kc data from the RFR ensemble model with ETEC data is warranted, acknowledging the limitation related to differences in data collection periods: ETEVI2 spans from 1 July 2023 to 31 March 2024, while ETPredicted Kc covers 3 February 2023 to 15 May 2024.
Evaluation metrics show that EVI2 consistently outperforms the RFR ensemble model, achieving a higher R2 (0.63 vs. 0.61), lower RMSE (0.67 vs. 0.86), and lower MAE (0.52 vs. 0.66), indicating superior accuracy. Additionally, EVI2 displays a mean percentage difference of 21.64%, significantly less than the RFR’s 29.65%. Statistical analyses further confirm EVI2’s superiority, with a higher Tau (0.643 vs. 0.607) and significant p-values in the MK test, indicating a more reliable trend. Furthermore, a higher Spearman’s rho (0.827 vs. 0.783) indicates a stronger correlation between predicted and observed values, with significant p-values.
These findings support the reliability and robustness of the EVI2 approach, making it the preferred method for estimating ET
a in this analysis. Furthermore, adopting ML to develop K
c prediction models is significantly data-intensive and technically demanding [
88]. This requirement for extensive in situ data poses challenges for smallholder farmers, who may lack the resources for detailed data-collection practices [
1]. Moreover, the reliance on accurate in situ NDVI values emphasises the complexity of correlating variables across diverse agronomic conditions.
While the RFR ensemble model was developed using a limited dataset of 86 temporally matched observations, a larger dataset spanning the full growing season may improve model reliability. A repeated ten-fold cross-validation procedure was used during model development; however, random partitioning does not preserve temporal ordering and may therefore influence the resulting performance metrics. Accordingly, the reported model performance should be interpreted in the context of the available dataset and the adopted validation framework and should not be regarded as evidence of temporal predictive transferability. Future research should evaluate the framework using larger longitudinal datasets and temporally structured validation approaches to strengthen confidence in model generalisability.
An additional limitation relates to the temporal aggregation of UAV-derived VIs prior to ET estimation. Monthly VI composites were used to represent canopy development between image acquisition dates; however, this approach may not fully capture short-term fluctuations in crop physiology and water stress under rainfed conditions. Consequently, daily ETa variability is driven primarily by changes in atmospheric demand via ET0, whereas vegetation dynamics are represented over a broader temporal scale.
Further research should investigate approaches that integrate higher-frequency observations, including satellite-based time series or more frequent UAV acquisitions, to better represent short-term vegetation responses and strengthen temporal continuity between image acquisition dates. Nevertheless, the objective of the present study was to evaluate the performance of operationally accessible ET–VI approaches under smallholder conditions rather than to develop a continuous daily physiological monitoring framework. Within this context, the methodology provides a practical means of assessing field-scale ET dynamics while maintaining the low data and computational requirements that are often necessary in resource-constrained agricultural systems [
1,
22].
4.5. Limitations and Recommendations for Future Research
Local EC data were used to validate the Kc prediction model and ET–VI methodologies, thereby enhancing reliability and supporting their application in the study context. However, to strengthen the credibility of these methods, future work should utilise a larger, more representative dataset that encompasses the full sugarcane growth cycle, beyond the 10 months considered in this study. Such datasets should incorporate a broader range of soil moisture conditions and diverse sugarcane genotypes across multiple regions to better capture variability in crop responses and environmental interactions. Furthermore, because the coefficient estimates were derived under rainfed conditions, they should be interpreted as reflecting integrated crop and water-stress responses rather than idealised crop development under non-limiting water availability. Although the framework demonstrated promising performance under the conditions investigated, its applicability across different sensor configurations was not explicitly evaluated. Given that the methodology relies on multispectral imagery and standardised ET–VI formulations rather than sensor-dependent thermal retrievals, it may offer greater flexibility across platforms; however, future validation across multiple sensors and environmental conditions is required to confirm broader applicability.
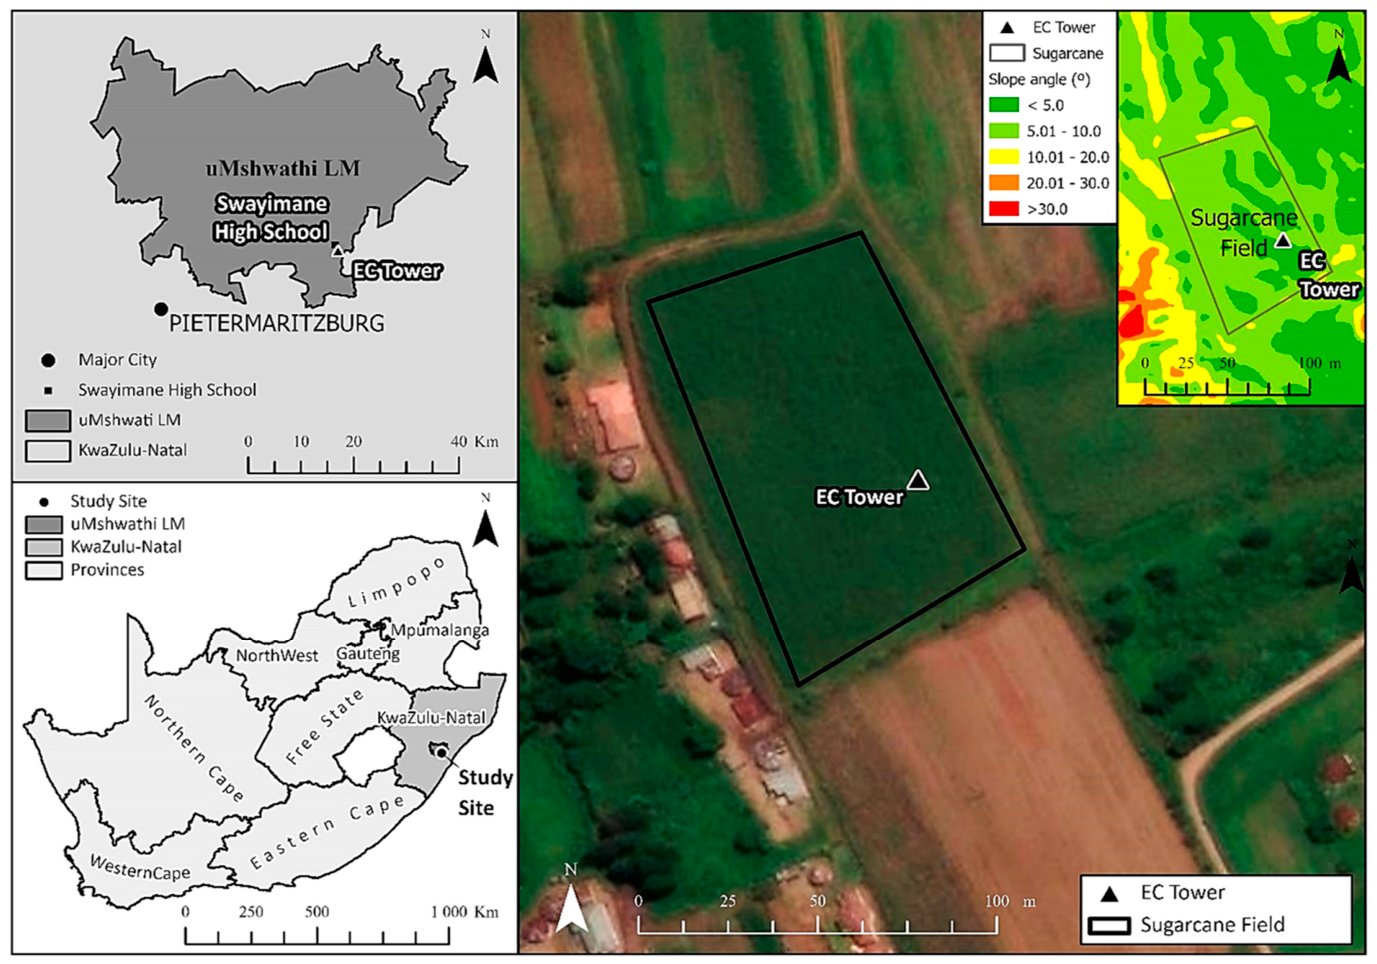
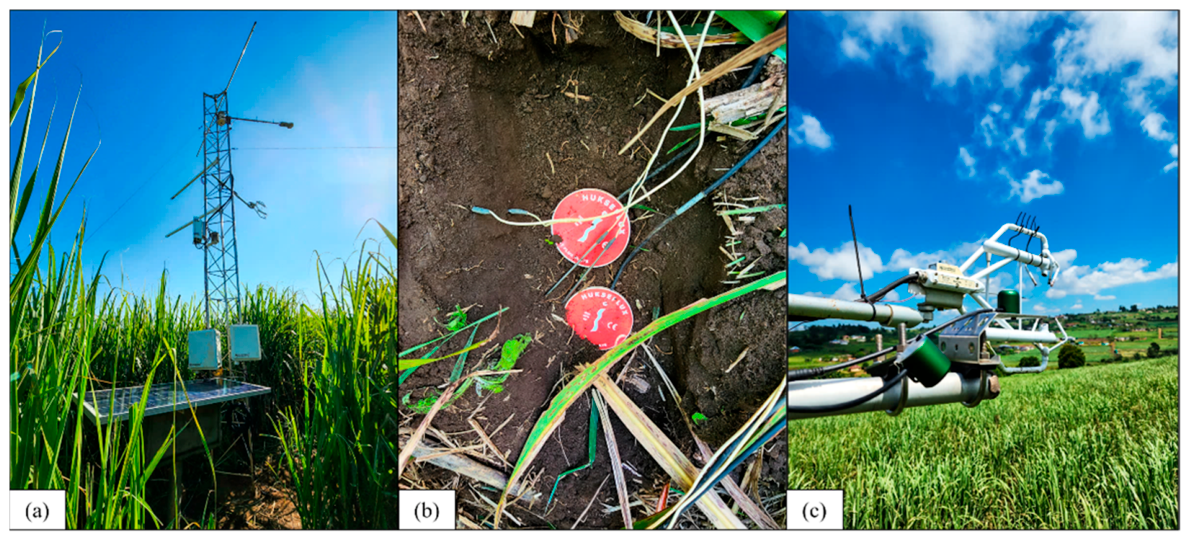
An additional consideration relates to the spatial correspondence between EC measurements and remotely sensed observations. The EC footprint varies over time in response to atmospheric stability, wind speed, and wind direction, whereas VIs were extracted as field-level averages. However, the relatively small extent of the study site, homogeneous sugarcane cover, and placement of the EC tower within the monitored field may reduce the magnitude of this mismatch. The EC measurement framework and site configuration employed in this study have also previously been applied and evaluated within the same experimental field [
54]. While footprint-informed extraction approaches may further strengthen spatial correspondence, field-average extraction remains a practical approach for small-scale agricultural studies where land cover is relatively uniform. Future research should evaluate the influence of dynamic footprint weighting on ET retrieval performance in heterogeneous agricultural environments.
Sugarcane Kc estimates were rapidly and accurately derived using UAV-based VIs and ground-based ET0. This methodology, applied to ET-VI products, relied on some empirical relationships. In addition, incorporating ground-based Kc and NDVI data to develop an ML ensemble model further enhanced its reliability. However, the need for on-site measurements limits the scalability and convenience of these models. Thus, future research should prioritise techniques that are less reliant on in situ data to enhance applicability for smallholder farmers facing challenges in accessing advanced measurement tools and ensuring consistent data collection.
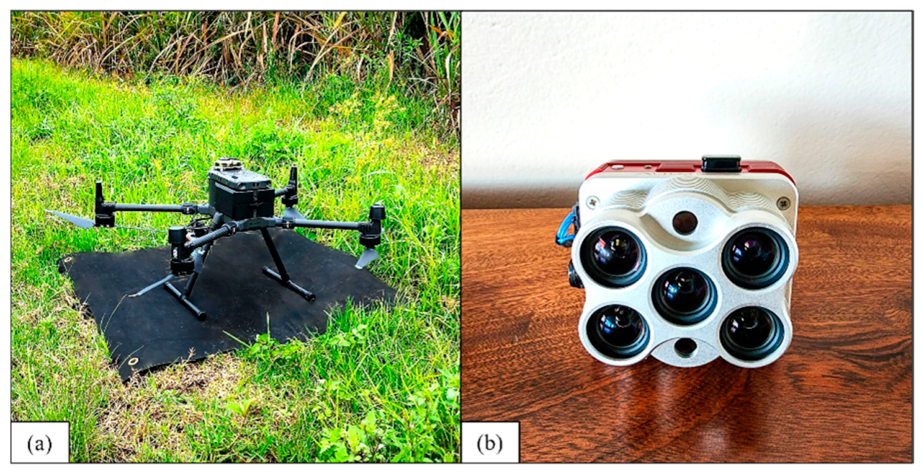
This research utilised a UAV equipped with a multispectral camera that captured images across five spectral bands, including visible and infrared regions, to obtain VIs. However, the costs associated with UAVs and the expertise and software required for processing add constraints, making this technology primarily viable as a research tool at present. To improve accessibility for smallholder farmers, future studies should examine the feasibility of incorporating more affordable RGB sensors alongside VI-based approaches for estimating ET
a [
22].
In light of the pressing challenges posed by climate change and population growth, efficient water management and increased crop yields are critical for local farmers. The findings of this research could significantly enhance sugarcane and crop production by improving water use efficiency and effectively managing crop-water stress. Decision support systems that integrate these results could equip farmers with valuable insights to optimise irrigation practices, ultimately improving crop yields, livelihoods, and food security while positively impacting local economies. Such tools could provide real-time data on crop stress indicators, enabling informed decision-making for effective resource management. In this context, the value of UAV-based ET estimation lies not in replacing conventional meteorological observations but in complementing them through spatially explicit characterisation of crop variability.
Importantly, the proposed framework is not intended to increase technological dependence or replace existing farm management practices. Rather, its value lies in supporting field-scale interpretation of crop water use through a computationally accessible ET workflow. Although UAV deployment may entail initial operational costs, simplified ET–VI approaches based on multispectral imagery may reduce analytical complexity compared with more sensor-intensive ET methodologies while improving the representation of within-field variability under heterogeneous smallholder conditions.
Despite their perceived simplicity, VI-based methodologies are prone to inaccuracies and biases [
89]. The NIR and R reflectance from the visible band typically yields higher resolution than thermal bands [
85,
90,
91]. However, these spectral bands are insufficient for capturing soil evaporation following irrigation and precipitation events, complicating drought and water stress assessments. Though the immediate effects of water scarcity on plant characteristics are generally minimal [
92], NDVI saturation in densely vegetated regions limits its reliability as an indicator of short-term variations in plant water stress.
EVI proves more effective in alleviating NDVI saturation, particularly in dense vegetation, by mitigating atmospheric influences and demonstrating reduced sensitivity to background noise [
93]. However, EVI’s dependence on a blue band may lead to low signal-to-noise ratios and potential instability [
35]. Consequently, EVI2 was introduced as a supplementary metric, circumventing the need for a blue band and offering greater noise resilience, thus enhancing its reliability as an index [
86,
94].
In summary, to maximise the benefits of these techniques for broader communities, future research should emphasise increasing the accessibility of technologies and tools that assist smallholder farmers in managing water resources and improving crop productivity amid the challenges of climate change and population growth.




 ,