Article

Data-Driven Machine Learning Prediction of Impact Failure in Cylindrical Lithium-Ion Batteries

1
Jiangsu Huadian Jurong Power Generation Co., Ltd., Zhenjiang 212499, China
2
Department of Mechanical Engineering, North China Electric Power University, Baoding 071003, China
3
College of Intelligent Equipment Manufacturing, Guangxi Vocational & Technical Institute of Industry, Nanning 530001, China
*
Authors to whom correspondence should be addressed.
Energies 2026, 19(6), 1435; https://doi.org/10.3390/en19061435
Submission received: 29 January 2026 / Revised: 1 March 2026 / Accepted: 5 March 2026 / Published: 12 March 2026
(This article belongs to the Special Issue Advances in Battery Modelling, Applications, and Technology)

Abstract

The mechanical safety of lithium-ion batteries (LIBs) under dynamic impact has been recognized as a critical concern for electric vehicles. In this study, three experimental dynamic impact datasets of cylindrical LIBs were established through drop-weight tests, with each dataset capturing the effects of indenter geometry, impact repetition, and state of charge (SOC). Using these datasets, six representative machine learning (ML) models—including ANN, SVR, LSTM, TCN, RF, and XGBoost—were evaluated for predicting force–time responses and analyzing failure-related characteristics indicated by the synchronized voltage response. The results indicated that ensemble models (XGBoost and RF) provided the highest predictive accuracy (R2 > 0.999) under the tested conditions, while temporal models (LSTM and TCN) effectively captured nonlinear time-dependent behavior. These findings demonstrate that ML-based prediction offers a rapid and reliable means for impact-response assessment and voltage-drop-based failure indication in cylindrical LIBs, supporting early-stage safety screening under the investigated impact conditions.

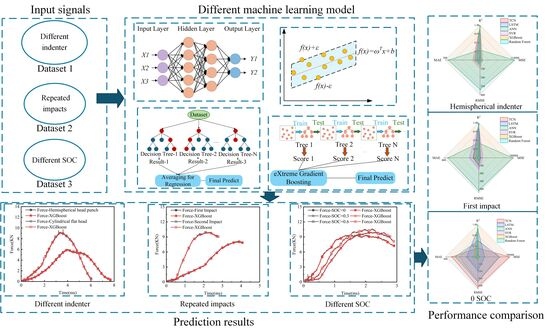
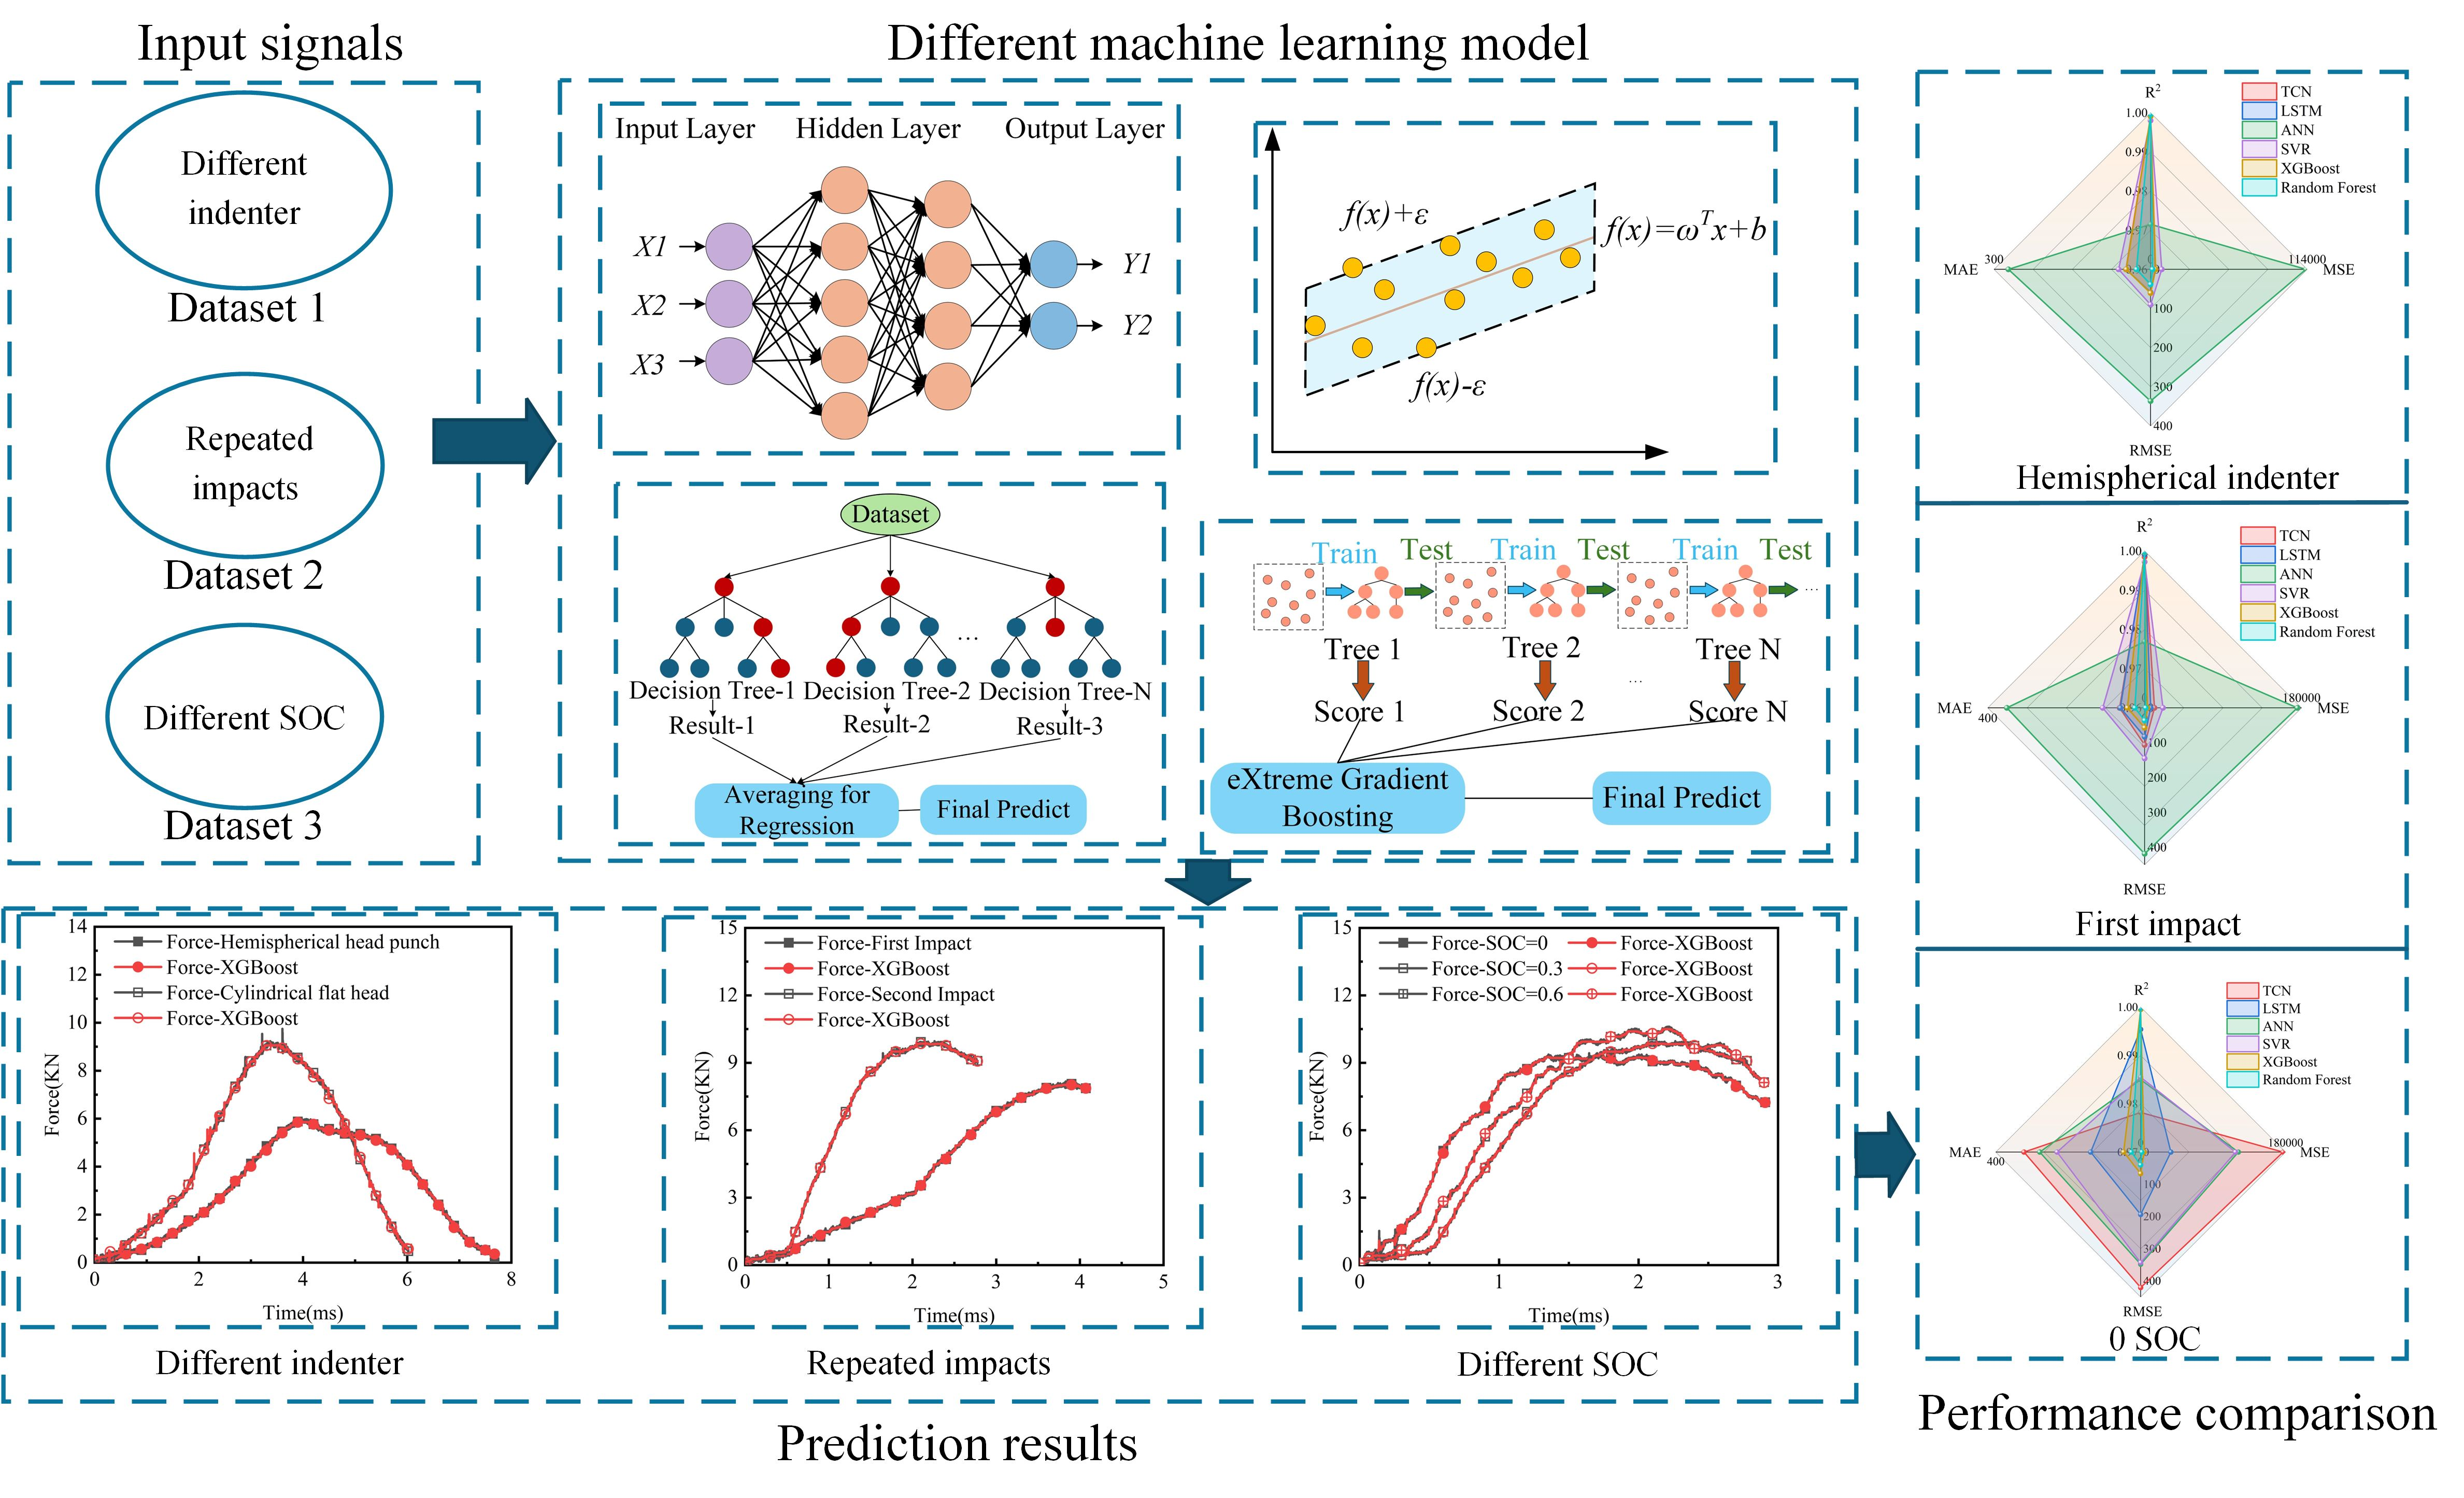
Graphical Abstract

1. Introduction

With the rapid expansion of the electric vehicle industry, the mechanical safety of lithium-ion batteries (LIBs) under abusive loading conditions is becoming a critical research focus. When exposed to external compression, drop, or impact forces, the electrodes and separators may buckle, tear, or puncture, resulting in internal short circuits (ISC) and, in severe cases, thermal runaway (TR), which can cause catastrophic safety failures [1,2,3,4,5]. Previous investigations have revealed that local stress concentration and shell buckling are dominant factors governing mechanical failure mechanisms under impact loading [6,7,8,9]. However, dynamic impact events are characterized by extremely high strain rates, brief deformation durations, and pronounced nonlinear behavior, making conventional empirical or threshold-based criteria inadequate for accurate prediction of failure initiation and progression. These features pose major obstacles to experimental measurement, failure identification, and comprehensive safety evaluation.
Compared with quasi-static loading, dynamic impact produces higher strain rates and faster load rise, resulting in highly sensitive LIB responses that depend strongly on boundary conditions. Experimental and numerical investigations have confirmed that indenter geometry, impact energy, and clamping configuration markedly affect the evolution of contact area, internal stress distribution, and failure modes [10,11,12,13]. It was demonstrated by Kociu et al. [10] through finite element (FE) simulations that varying loading paths caused distinct changes in stress concentration and plastic zone formation. It was reported by Chen et al. [11] based on repeated impact experiments that contact form and boundary constraints directly influenced the peak force (PF) and failure initiation. It has further been indicated in review analyses that indenter curvature, support configuration, and lateral constraint modify shell buckling behavior and potential short-circuit (SC) initiation sites [12]. It was shown by Huang et al. [13] that cylindrical LIBs exhibit coupled deformation features, including shell buckling, electrode fracture, and localized stress concentration, which collectively govern mechanical degradation and SC onset. The state of charge (SOC) also exerts a strong effect on dynamic response. It was identified by Cioni et al. [14] that LIBs at higher SOC displayed greater stiffness and PF, making them more prone to SC at smaller deformation levels. It was revealed by Xu et al. [15] that increasing SOC reduced the safe deformation range and triggered earlier voltage drops, while it was found by Wang et al. [16] that the influence of SOC became more significant under elevated strain rates. Repeated impacts additionally generate irreversible internal damage and exhibit clear cumulative behavior [17,18]. These observations highlight the necessity of establishing a multi-condition dataset that integrates indenter geometry, impact repetition, and SOC for comparative analysis across conditions and data-driven modeling of LIBs. Experimental observation combined with FE simulation provides crucial insight into the mechanical failure of batteries. In recent years, digital image correlation (DIC) techniques have been extensively applied in abuse testing, enabling full-field strain and displacement measurement for validation and structural characterization [19,20]. Advances in multi-scale and coupled electro–thermal–mechanical FE modeling allow simultaneous simulation of shell deformation, jellyroll compression, stress redistribution, and electrothermal interaction within unified computational frameworks [21,22,23]. An FE model of cylindrical LIBs was developed by Sahraei et al. [21], which retained key geometric details while substantially reducing computational cost, thereby facilitating the localization of potential SC regions. It was reported by Mama et al. [22] and Wang et al. [23] that meso-scale frameworks effectively captured local damage and heat transfer across electrodes and separators, whereas macro-scale approaches are better suited for module-level analysis. Nevertheless, parameter transfer between scales still depends on extensive calibration. Although fully coupled FE models reproduce experimental trends, their heavy computational burden and parameter sensitivity restrict their use in fast prediction and cross-scenario evaluation under variable impact and SOC conditions [24,25,26]. In this context, data-driven strategies have emerged as an effective complement to dynamic safety evaluation of LIBs. With the expanding availability of experimental data and computational resources, machine learning (ML) methods are increasingly employed in mechanical abuse studies to identify nonlinear correlations among multi-source signals. Jia et al. [27] proposed a multi-physical-signal-based prediction framework for risk assessment, achieving precise recognition of SC events and failure initiations under loading conditions. Götz et al. [28] applied multiple machine-learning and ensemble methods to operational battery data for fault diagnosis, highlighting the effectiveness of data-driven safety assessment. Zhao et al. [29] constructed a multi-signal fusion neural network for early failure warning, whereas Zhang et al. [30] introduced a deep-learning framework capable of predicting impact-induced failure with limited data. Zhang et al. [31] provided a critical review of thermal runaway prediction and early-warning methods, summarizing data-driven safety assessment strategies and the key challenges for reliable early warning. Hu et al. [32] reviewed thermal runaway warning technologies and emphasized that battery management systems combined with intelligent algorithms can enhance predictive capability by leveraging multi-source signals, including electrical indicators. Recent advances in electrochemical signal interpretation and potentiometric sensing further support the use of voltage-related signals as informative indicators for data-driven assessment [33]. Wang et al. [34] proposed a machine-learning-based early-stage ISC detection framework using electrochemical impedance spectroscopy and demonstrated its effectiveness across multiple cylindrical-cell datasets with transfer-learning evaluation. Data-driven modeling has also proven effective in representing intricate mechanical behaviors in structural and materials research [35,36], and in state estimation of LIB systems [37], providing methodological guidance for data-driven safety assessment of LIBs under dynamic loading.
However, current investigations still face three critical limitations. First, there is no unified dynamic impact dataset that consistently integrates indenter geometry, impact repetition, and SOC within a single experimental framework, which restricts cross-condition comparison and limits rigorous evaluation of model generalization. Second, most machine learning models have been evaluated in isolation, and their predictive accuracy and robustness across diverse algorithms and loading conditions have not been systematically compared under a standardized preprocessing and validation pipeline. Third, evaluation rigor and data independence under densely time-sampled impact signals are often insufficiently clarified, which may lead to optimistic performance estimates; meanwhile, physical interpretability and robustness to signal quality remain under-discussed for deployment-oriented impact safety assessment.
To address these gaps, this study experimentally established a unified multi-condition dynamic impact dataset of commercial cylindrical LIBs through drop-weight tests covering different indenter geometries, repeated impacts, and SOC levels. Six representative ML models, including ANN, SVR, LSTM, TCN, RF, and XGBoost, were systematically evaluated using a consistent preprocessing and evaluation protocol. The objective was to compare their prediction performance for force–time responses under the tested impact conditions and to provide a data-driven approach for impact-response prediction with voltage-drop-based failure indication in cylindrical LIBs. This work supports rapid impact-response assessment and preliminary safety screening for battery protection design.

2. Methodology

2.1. Specimens and Experimental Setup

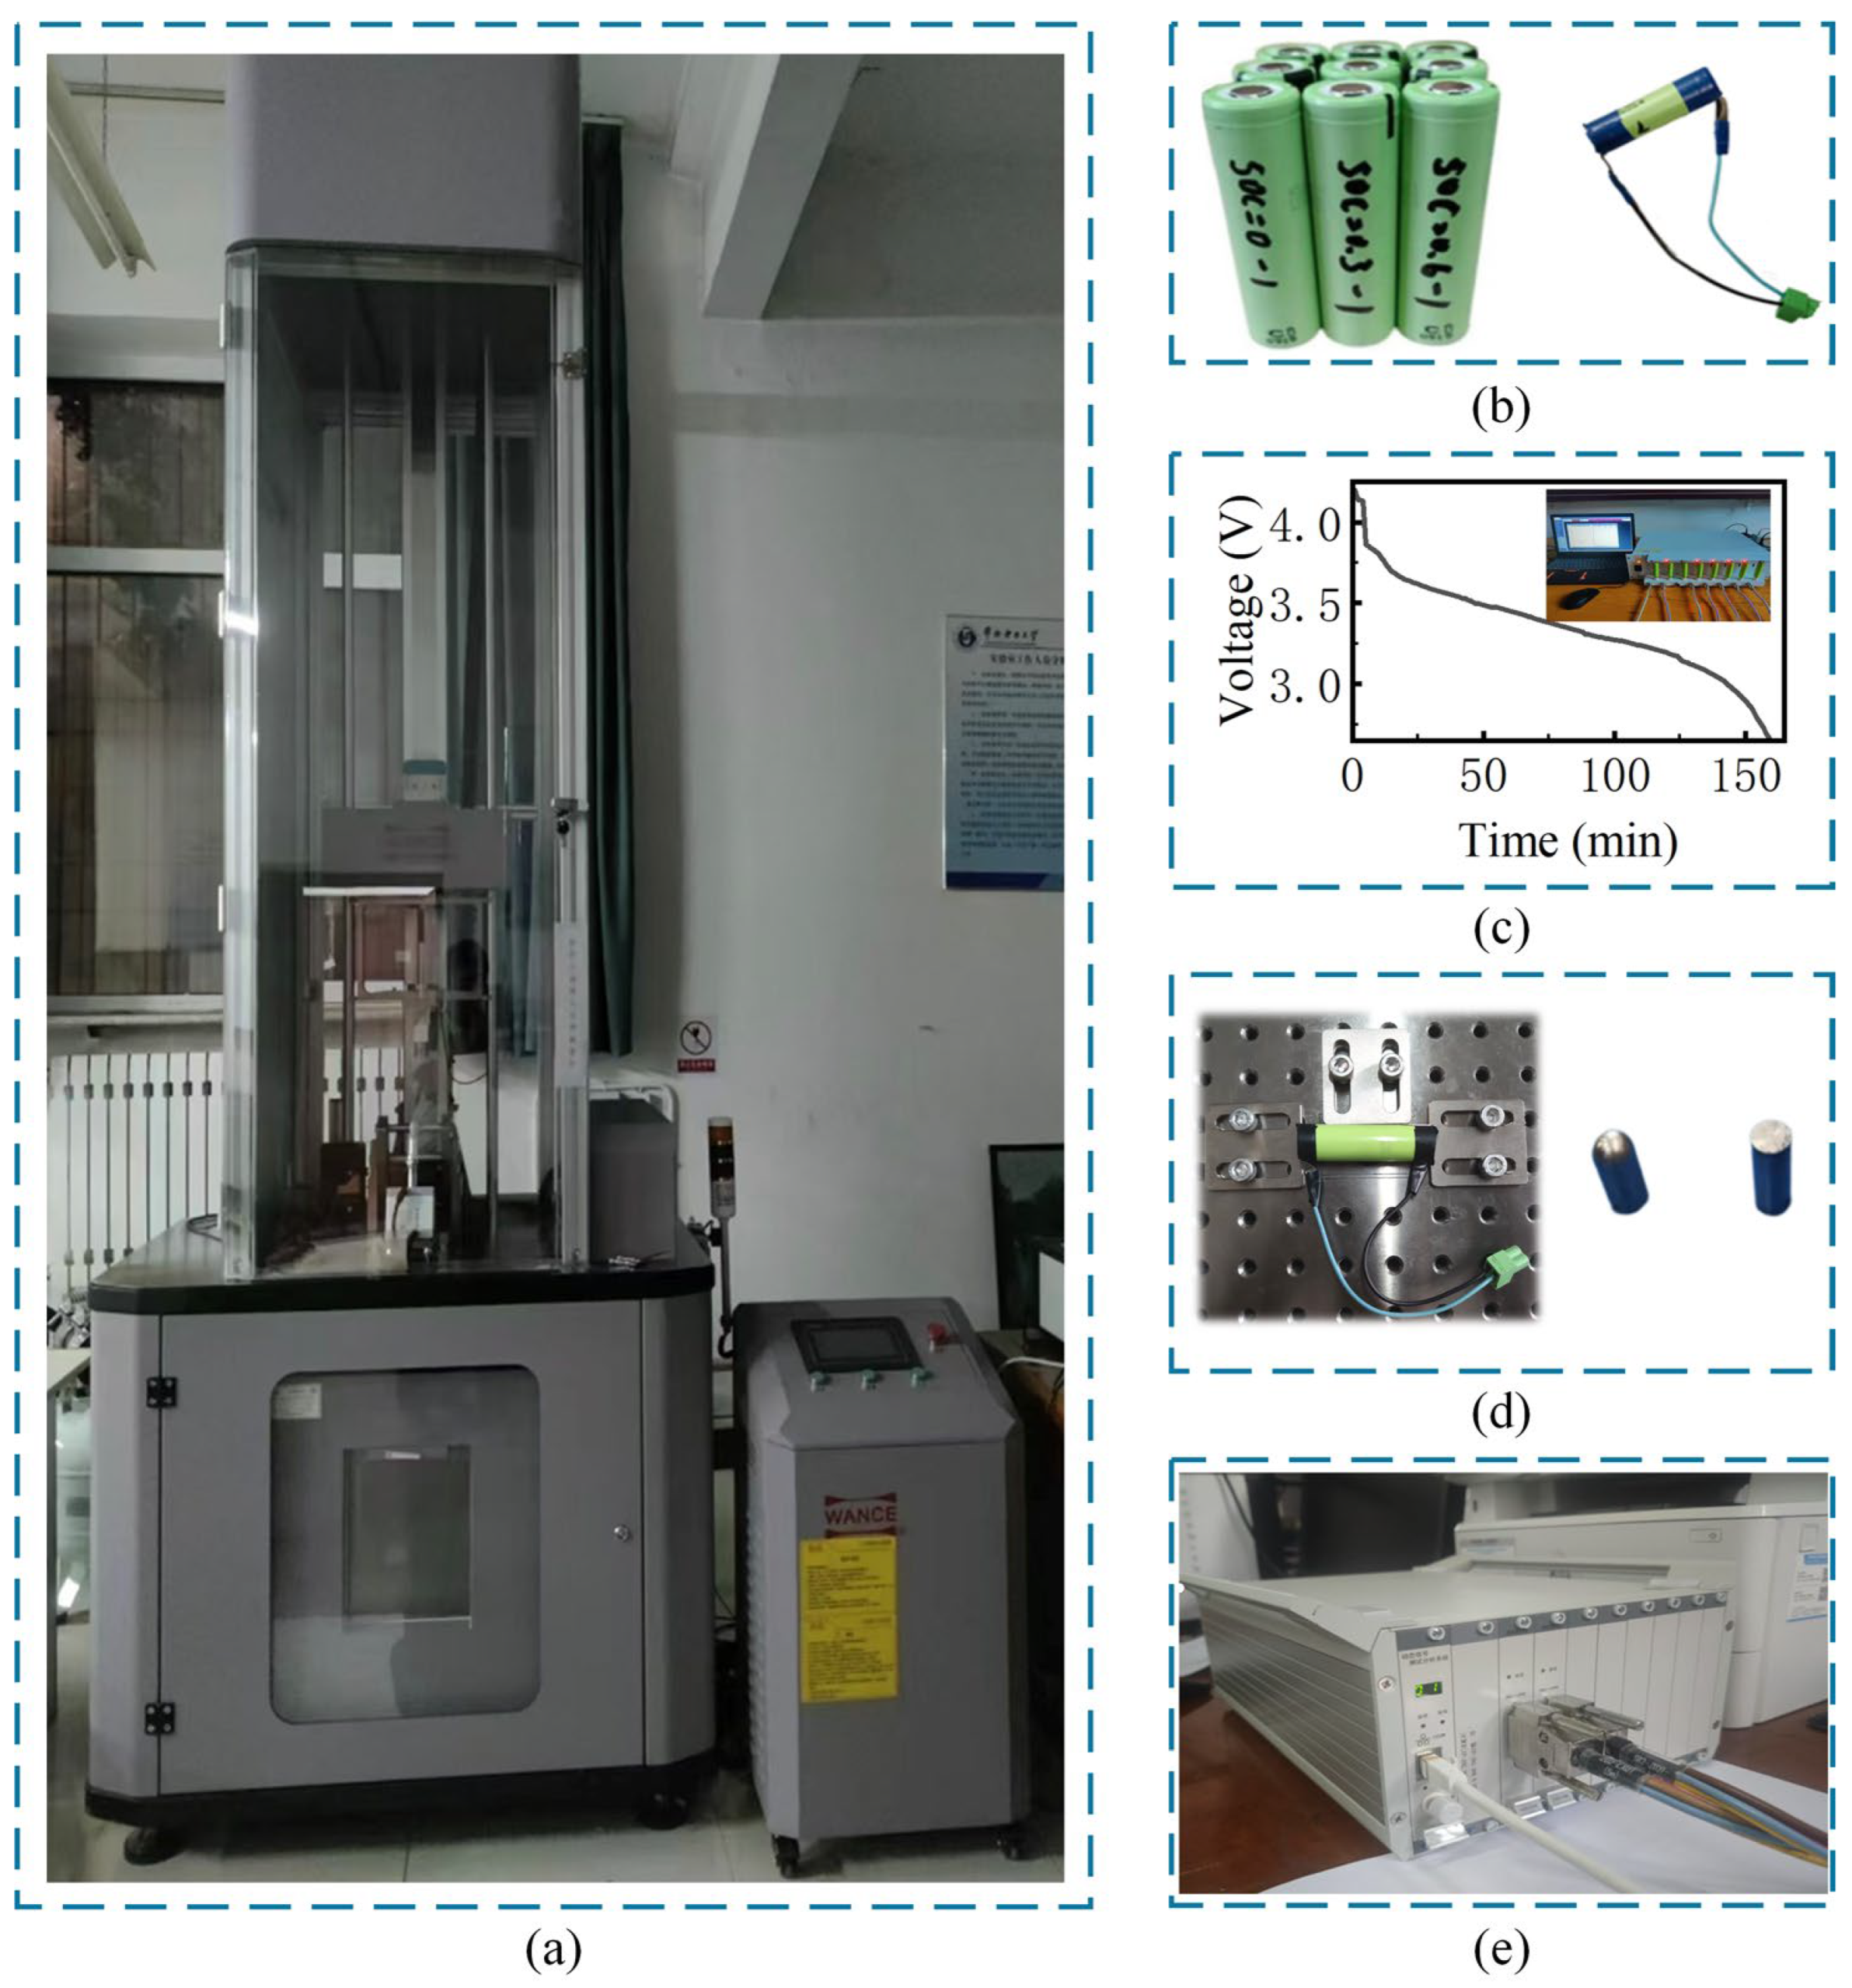
Commercial cylindrical LIBs (Panasonic NCR18650B, Moriguchi-shi, Osaka, Japan) were selected as the test specimens. Each LIB was measured to be 65 mm in length and 18 mm in diameter, as shown in Figure 1b, and the principal specifications are listed in Table 1. The LIB consisted of a cathode, an anode, a separator, an electrolyte, and a metallic casing. The cathode comprised lithium nickel cobalt manganese oxide (LiNiCoMnO2) coated on an aluminum current collector, whereas the anode contained graphite material deposited on a copper current collector. The separator was positioned between the electrodes to prevent direct electronic contact while permitting lithium-ion transport.
To ensure uniform initial conditions and verify the nominal capacity, all batteries underwent one complete charge–discharge cycle before impact testing. The cycling procedure was performed using a high-precision LIB tester (5 V/3 A, eight channels, Shenzhen, China). The target SOC was determined by coulomb counting based on the measured discharge capacity from the pre-conditioning cycle. Cells were then discharged at a constant current of 0.3 C to the designated SOC levels of 0%, 30%, and 60%, where 0% SOC corresponds to 100% depth of discharge (DOD). After reaching the target SOC, all specimens rested for at least 24 h to minimize polarization and stabilize the electrochemical state prior to testing. The SOC levels were selected to span a deeply discharged baseline and two representative mid-range operating states, while maintaining test safety and repeatability.
Dynamic impact experiments were performed using a WANCE DIT302E drop-weight impact system (Shenzhen, China), as shown in Figure 1a. The drop hammer had a mass of 10 kg. Before each impact, a small initial clearance was maintained between the indenter and the battery surface to prevent unintended secondary contact. The detailed experimental setup and two types of indenters (flat and hemispherical) are presented in Figure 1d. During testing, the impact force and displacement signals were synchronously recorded at a sampling frequency of 100 kHz. The LIB voltage was simultaneously acquired using a high-speed data acquisition card (Shenzhen, China) synchronized with the mechanical channels, as shown in Figure 1e.

2.2. Dataset Generation

A dynamic impact failure dataset for cylindrical LIBs was established using experimental data collected from the WANCE DIT302E drop-weight impact system. Time, voltage, and force signals were recorded simultaneously by the equipment, forming the foundation for subsequent model training and feature extraction. The experimental design incorporated three principal variables—indenter geometry, impact repetition, and SOC—to comprehensively characterize the mechanical failure responses of LIBs under representative dynamic loading conditions.
Based on different test configurations, three datasets were constructed for subsequent analysis. Impacts conducted with different indenter geometries were assigned to Dataset 1. Impacts conducted under repeated loading conditions were assigned to Dataset 2. Impacts conducted at various SOC levels were assigned to Dataset 3. The detailed experimental parameters and sample numbers for each dataset are summarized in Table 2.
The dynamic impact dataset contained multi-dimensional features, including time, voltage, force, and test condition parameters. The constructed dataset was used as the foundation for applying multiple ML algorithms in the subsequent sections to model and predict the mechanical failure behavior of the LIBs, with the aim of evaluating the applicability and predictive accuracy of different approaches under complex loading conditions.
It should be noted that the “Number of samples” in Table 2 refers to the number of time-sampled points used for model development, rather than the number of independent impact tests. For each loading condition listed in Table 2, one independent impact event was recorded, and time-sampled points were extracted from the valid impact window of that impact history to form the modeling dataset.
The raw force and voltage signals were recorded at a sampling frequency of 100 kHz. Prior to model development, basic preprocessing was performed, including removal of obvious acquisition errors, extraction of the valid impact window based on the onset of the force response, and normalization of input variables. No aggressive filtering was applied in order to preserve the intrinsic dynamic characteristics of the impact signals.
Following a standardized training and testing protocol, the dataset was split into 70% for training and 30% for testing. All six models were trained and evaluated using the same split to ensure a fair comparison. The 70% training and 30% testing split was performed at the time-point level within each loading condition, so time points from the same impact event may appear in both subsets and are temporally correlated. Accordingly, the reported metrics mainly reflect pointwise prediction performance under the present experimental setup rather than strict generalization to unseen impact events. Cross-validation at the time-point level was not adopted because it would mix temporally correlated samples across folds and could yield optimistic estimates; event-level cross-validation will be considered in future work when additional independent impact tests per condition become available.

3. Model and Performance Evaluation

3.1. Problem Description

Based on multi-condition dynamic impact experiments, a data-driven prediction model for cylindrical LIBs was developed to analyze their mechanical responses under various loading conditions. The primary objective of this study was to predict the mechanical force evolution and corresponding failure characteristics during impact, using input features such as voltage time-series signals and operational parameters, including indenter geometry, number of impacts, and SOC.
To model the complex mechanical failure behavior of cylindrical LIBs under impact loading, six representative ML algorithms were employed: temporal neural networks (LSTM, TCN), ensemble learning (RF, XGBoost), and kernel-based regression (SVR, ANN). These models were selected for their ability to capture the high nonlinearity and complex relationships between input variables (such as impact parameters and voltage) and the target output (impact force). Temporal models, like LSTM and TCN, are particularly suited for learning sequential dependencies, while ensemble methods and kernel-based models excel in capturing complex patterns from high-dimensional data. By applying these models, we aimed to systematically evaluate their predictive performance under challenging, multi-condition scenarios.
In this study, model performance corresponds to pointwise prediction accuracy on densely time-sampled force trajectories under the present experimental setup. The dataset split was conducted at the time-point level, and the reported metrics therefore primarily reflect pointwise prediction performance of measured force–time histories and may be optimistic due to temporal correlation.
The ML models were trained to predict the instantaneous impact force along the recorded impact history. Failure onset was not predicted as a separate label, but was inferred from the voltage-drop criterion together with its temporal relation to the predicted force response.
Time was included as an input to indicate the impact stage within an event and to support pointwise regression of force conditioned on voltage and loading parameters. Accordingly, the present formulation focuses on predicting the force–time response within the recorded impact window rather than forecasting beyond the observed time range.
The raw force and voltage signals were recorded at 100 kHz. Basic preprocessing was applied before model development, including removal of obvious acquisition errors, extraction of the valid impact window based on the onset of the force response, and normalization of input variables. No aggressive filtering was applied to preserve the intrinsic dynamic characteristics of the impact signals.
For model development, time-sampled points were organized in a tabular form and randomly divided into 70% training data and 30% testing data. All six models used the same split for fair comparison. Since all experiments were conducted using the same equipment, acquisition settings, and cell type, systematic batch effects were considered negligible under the present experimental setup.

3.2. ML Models

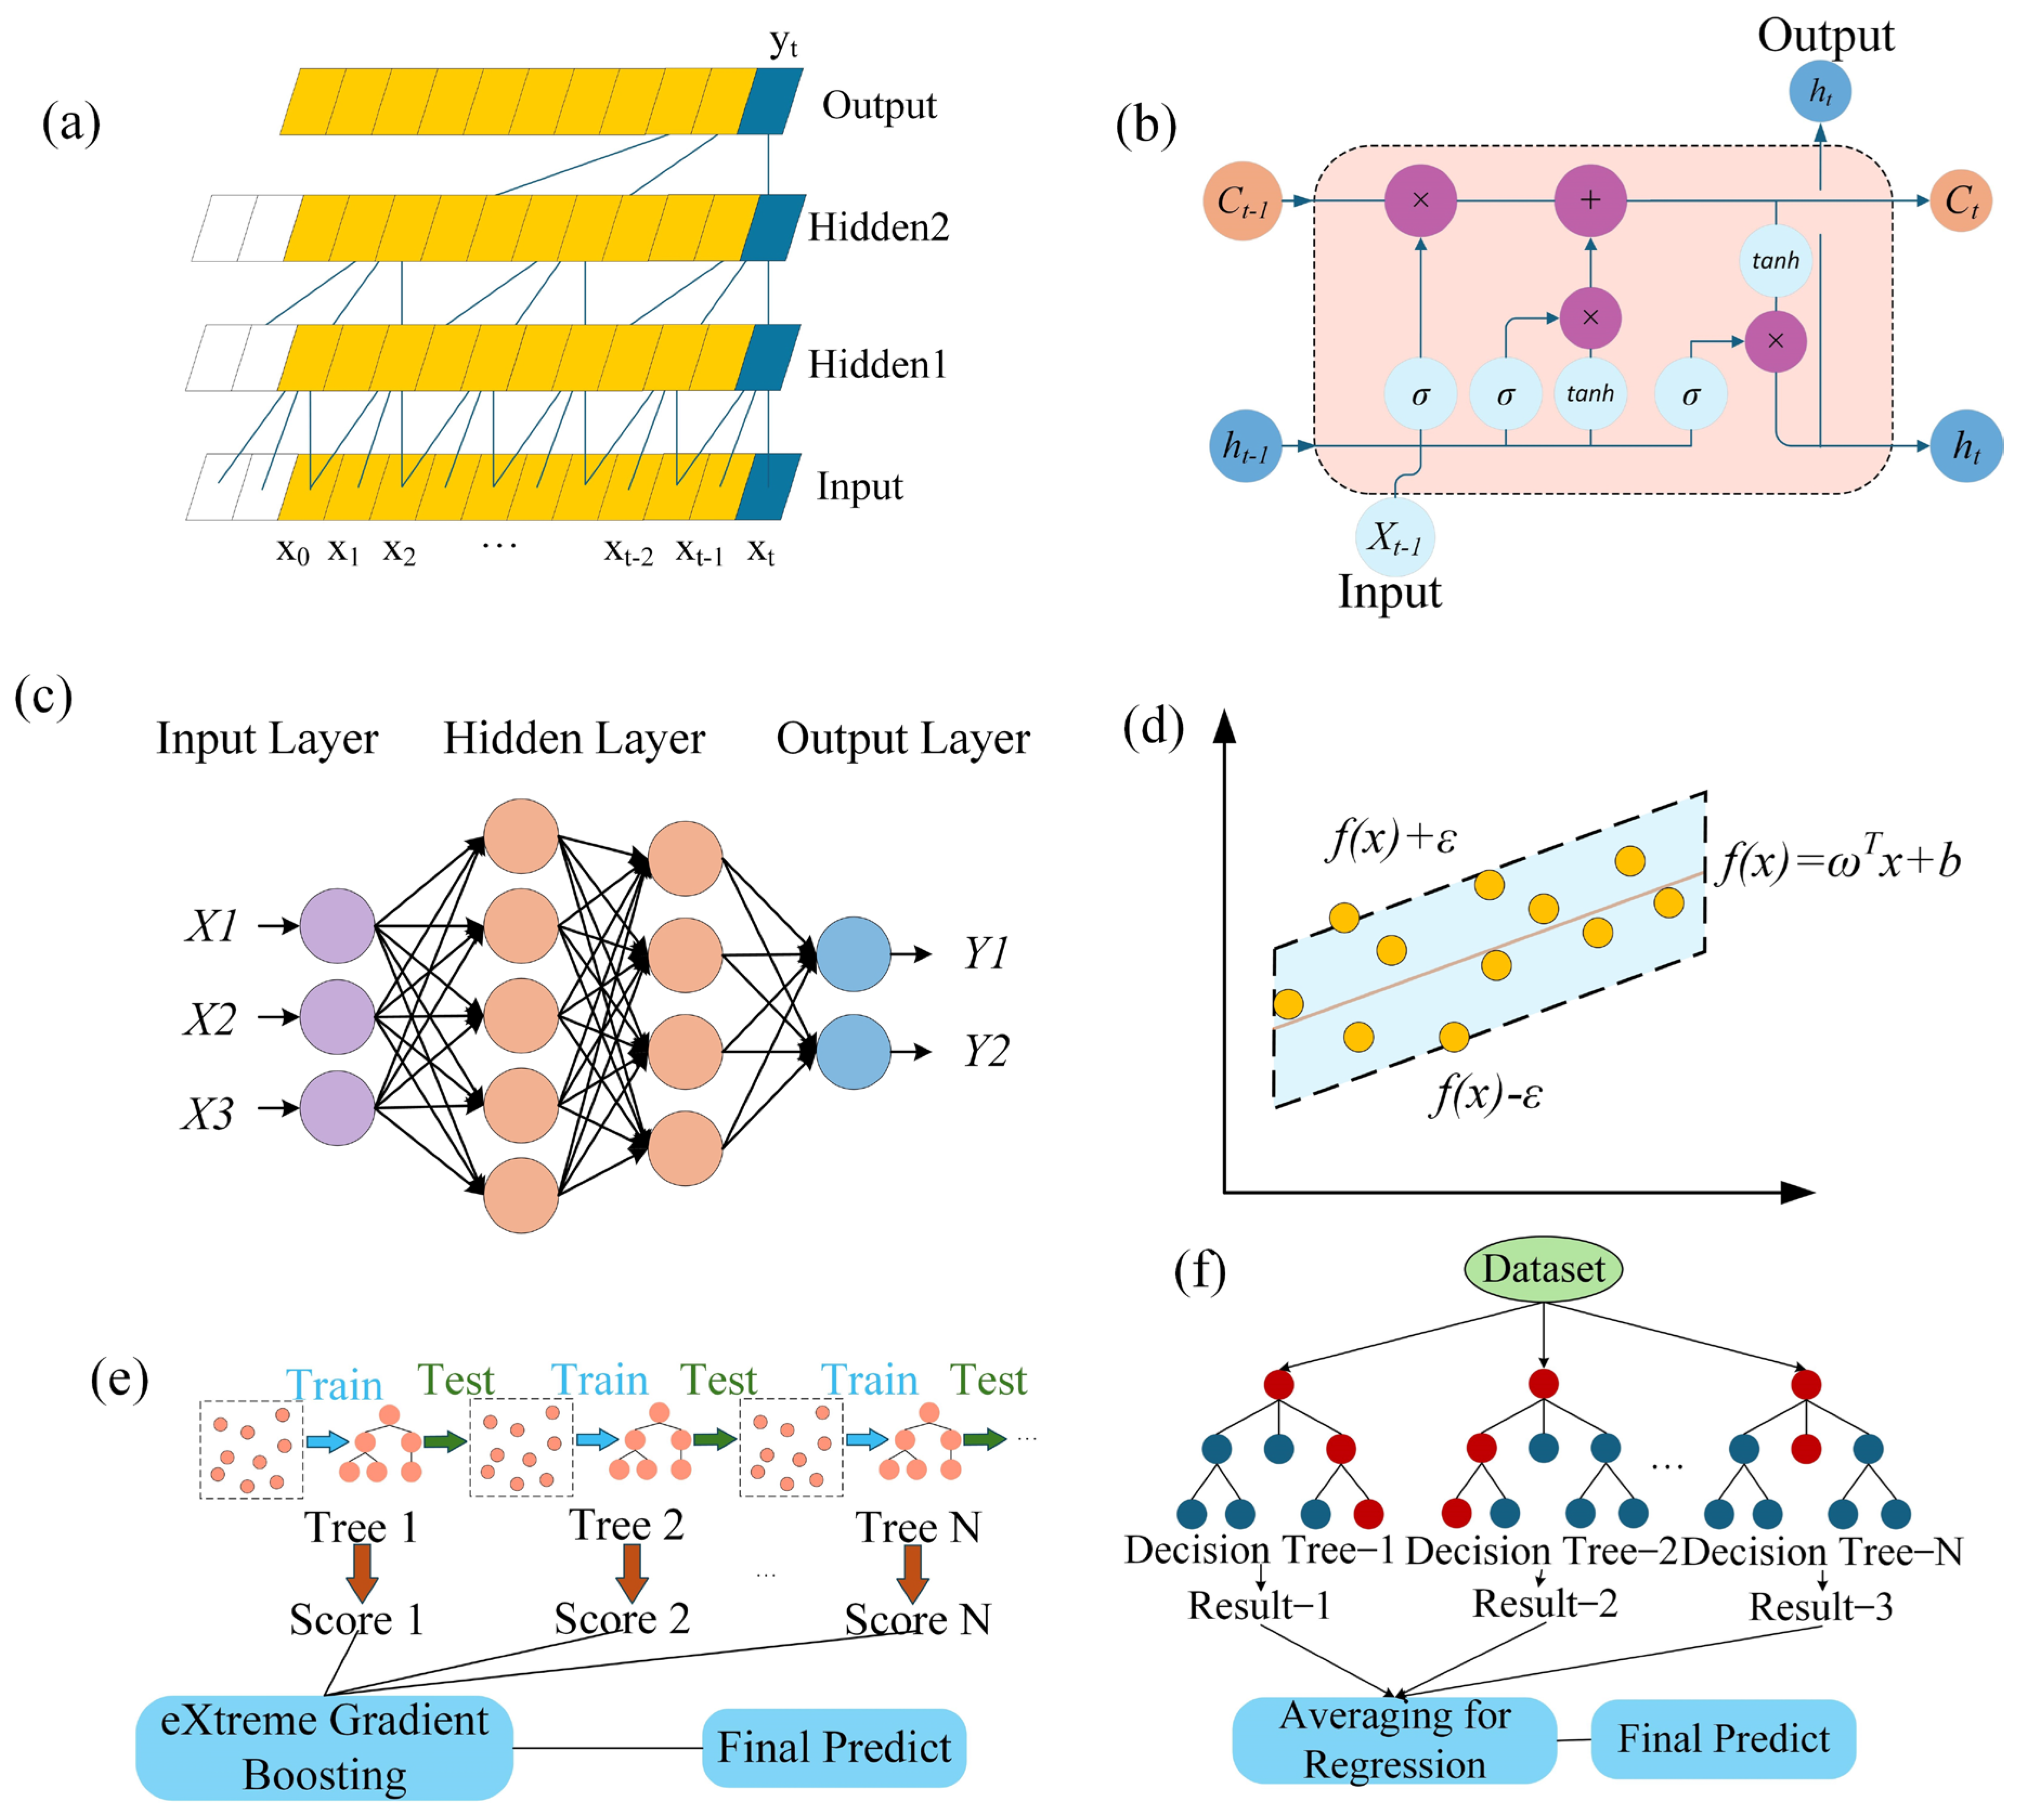
The prediction of mechanical failure in cylindrical LIBs under impact loading was formulated as a multi-input nonlinear regression task. To tackle this, six representative machine learning models were implemented: temporal models such as LSTM and TCN, a kernel-based regression model such as SVR and a feedforward neural-network baseline such as ANN, and ensemble learning models like RF and XGBoost. The architectures and working principles of these six ML models are illustrated in Figure 2, including TCN in Figure 2a, LSTM in Figure 2b, ANN in Figure 2c, SVR in Figure 2d, XGBoost in Figure 2e, and RF in Figure 2f. These models were selected for their ability to model complex, nonlinear relationships between input variables such as impact parameters and voltage, and the target output of impact force. Temporal models capture sequential dependencies, ensemble methods leverage multiple decision trees, and kernel methods efficiently handle high-dimensional data.
Deep temporal neural networks, including the LSTM and TCN, were employed to capture sequential dependencies within the impact signals. The LSTM addresses the gradient-vanishing issue inherent in traditional recurrent neural networks through its gated mechanism and preserves long-term temporal information, making it suitable for nonlinear time-series prediction involving repeated impacts and different SOC levels. The TCN uses a one-dimensional causal convolution with dilated kernels to expand the receptive field, enabling efficient extraction of transient features and short-term variations under dynamic impact loading.
General neural-network and kernel-based regression methods, represented by the ANN and SVR, were also evaluated. In ANN, nonlinear multi-layer mappings are performed to capture complex relationships between input variables and mechanical responses, although its ability to model high-frequency temporal variations is limited. In SVR, kernel functions are employed to project input features into a high-dimensional feature space, allowing nonlinear regression with strong robustness to noisy or small-sample datasets.
Ensemble learning models, including RF and XGBoost, were implemented to assess tree-based predictive mechanisms. In RF, an ensemble of decision trees with randomized feature sampling is constructed to reduce model correlation and overfitting, which helps mitigate overfitting in tree-based regression. In XGBoost, the gradient boosting framework is followed, and weak learners are integrated through iterative optimization. This model follows a gradient-boosting formulation and incorporates regularization through its standard objective and penalty terms.
All models were trained and evaluated using the datasets established in Section 2.2. The input variables included time, voltage, and impact parameters, while the output represented the mechanical force during the impact process. By comparing the predicted force–time responses and evaluation metrics within each dataset under the same evaluation protocol, differences in accuracy among models under the present experimental setup were systematically analyzed.
All six models were implemented using standard Python libraries. The software versions used in this study were Python 3.12, PyTorch 2.6, scikit-learn 1.7.2, and XGBoost 3.1.3. The complete hyperparameter settings for ANN, SVR, LSTM, TCN, RF, and XGBoost, together with the random seed and software versions, are provided in Table 3 to ensure full reproducibility. Hyperparameters were kept identical across loading conditions and were not modified using information from the test set.

3.3. Model Performance Evaluation Metrics

To quantitatively evaluate the accuracy of the models in predicting the mechanical failure of LIBs, four commonly used statistical indicators were adopted: the coefficient of determination (R2), mean squared error (MSE), root mean squared error (RMSE), and mean absolute error (MAE). Their formulations are expressed as follows:
R 2 = 1 i ( y ^ F i y F i ) 2 i ( y ¯ F i y F i ) 2
MSE = 1 n i = 1 n ( y F i y ^ F i ) 2
RMSE = 1 n i = 1 n ( y F i y ^ F i ) 2
MAE = 1 n i = 1 n ( y F i y ^ F i ) 2
where n represents the number of data samples, y F i denotes the actual mechanical force of the lithium-ion battery, y ^ F i is the corresponding predicted mechanical force, and y ¯ F i refers to the mean value of the actual mechanical force.
The coefficient of determination (R2) reflects the model’s ability to explain the variance of the observed data; values closer to 1 indicate better fitting performance. MSE and RMSE quantify the overall deviation and fluctuation of the prediction errors, where smaller values correspond to higher prediction accuracy. MAE measures the average magnitude of the prediction errors, providing an intuitive representation of the model’s overall deviation across all samples. By jointly analyzing R2, RMSE, and MAE, the predictive precision and stability of different models under dynamic loading conditions can be comprehensively assessed.

4. Results and Discussion

4.1. Data Characteristic Analysis

Operational definition of failure. In this work, impact-induced failure associated with ISC was identified from the synchronized voltage response. A failure event was defined as the first abrupt and non-recoverable voltage drop during the impact process, which is clearly distinguishable from the pre-impact baseline fluctuation. The corresponding mechanical stage can be characterized by a rapid decrease in force after the peak. The ML models were trained to predict the force–time response along the impact history, and failure onset was inferred based on the voltage-drop criterion together with its temporal relation to the predicted force trajectory. It should be noted that cross-condition transfer learning was not performed; models were trained and tested within each dataset using a time-point-level split, and the reported results mainly reflect reconstruction performance under the present experimental setup.
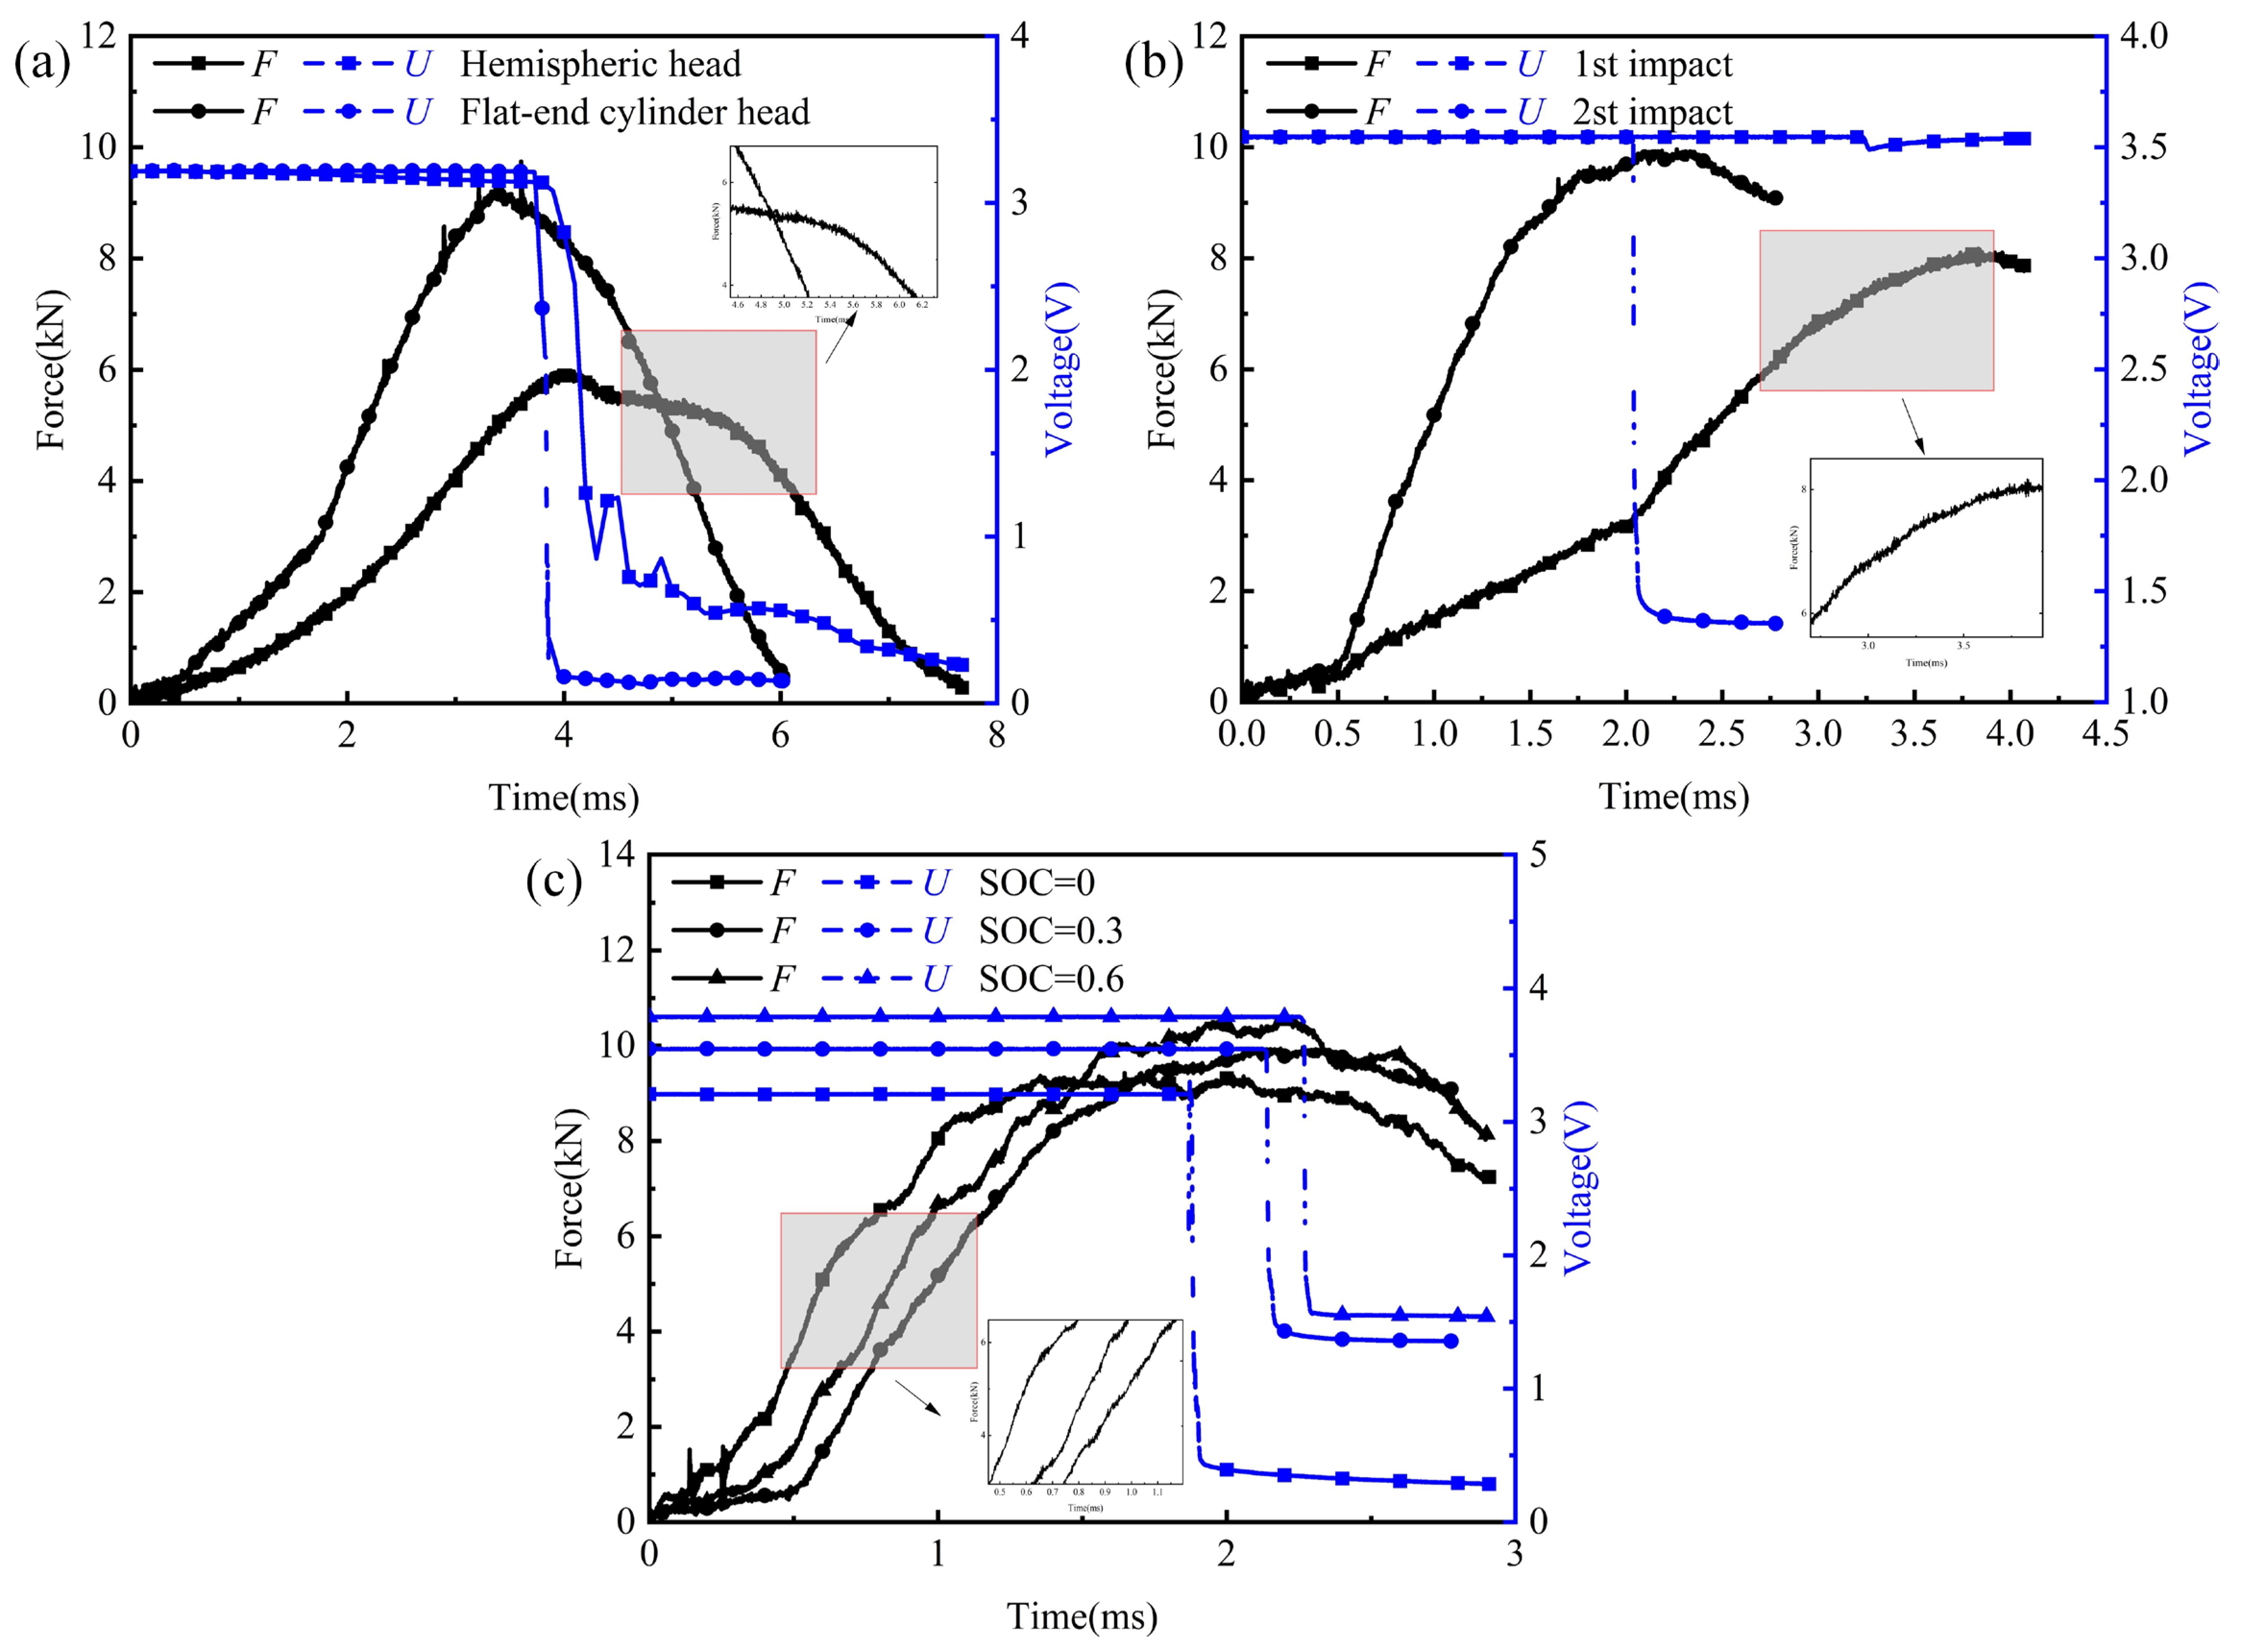
Figure 3 presents the dynamic mechanical responses of cylindrical LIBs under impact loading. As the impact time increased, the force on the LIB rose steadily until mechanical failure occurred. After failure, a sharp voltage drop accompanied by a rapid decrease in force was observed. These responses indicate the initiation of ISC and the subsequent loss of load-carrying capacity.
Under different indenter geometries, as shown in Figure 3a, the cylindrical flat indenter produced a higher PF than the hemispherical one. This difference is consistent with its larger contact area and the resulting stress concentration, which promotes local deformation. In repeated impact tests, as shown in Figure 3b, the first impact caused a negligible voltage change, while the second impact induced a sudden voltage drop concurrent with the force peak, reflecting cumulative internal damage and earlier voltage collapse. For tests at different SOC, as shown in Figure 3c, higher SOC resulted in delayed voltage drops but significantly higher PFs, as increased electrode stiffness reduced the LIB’s deformability.

4.1.1. Prediction Under Different Indenter Conditions

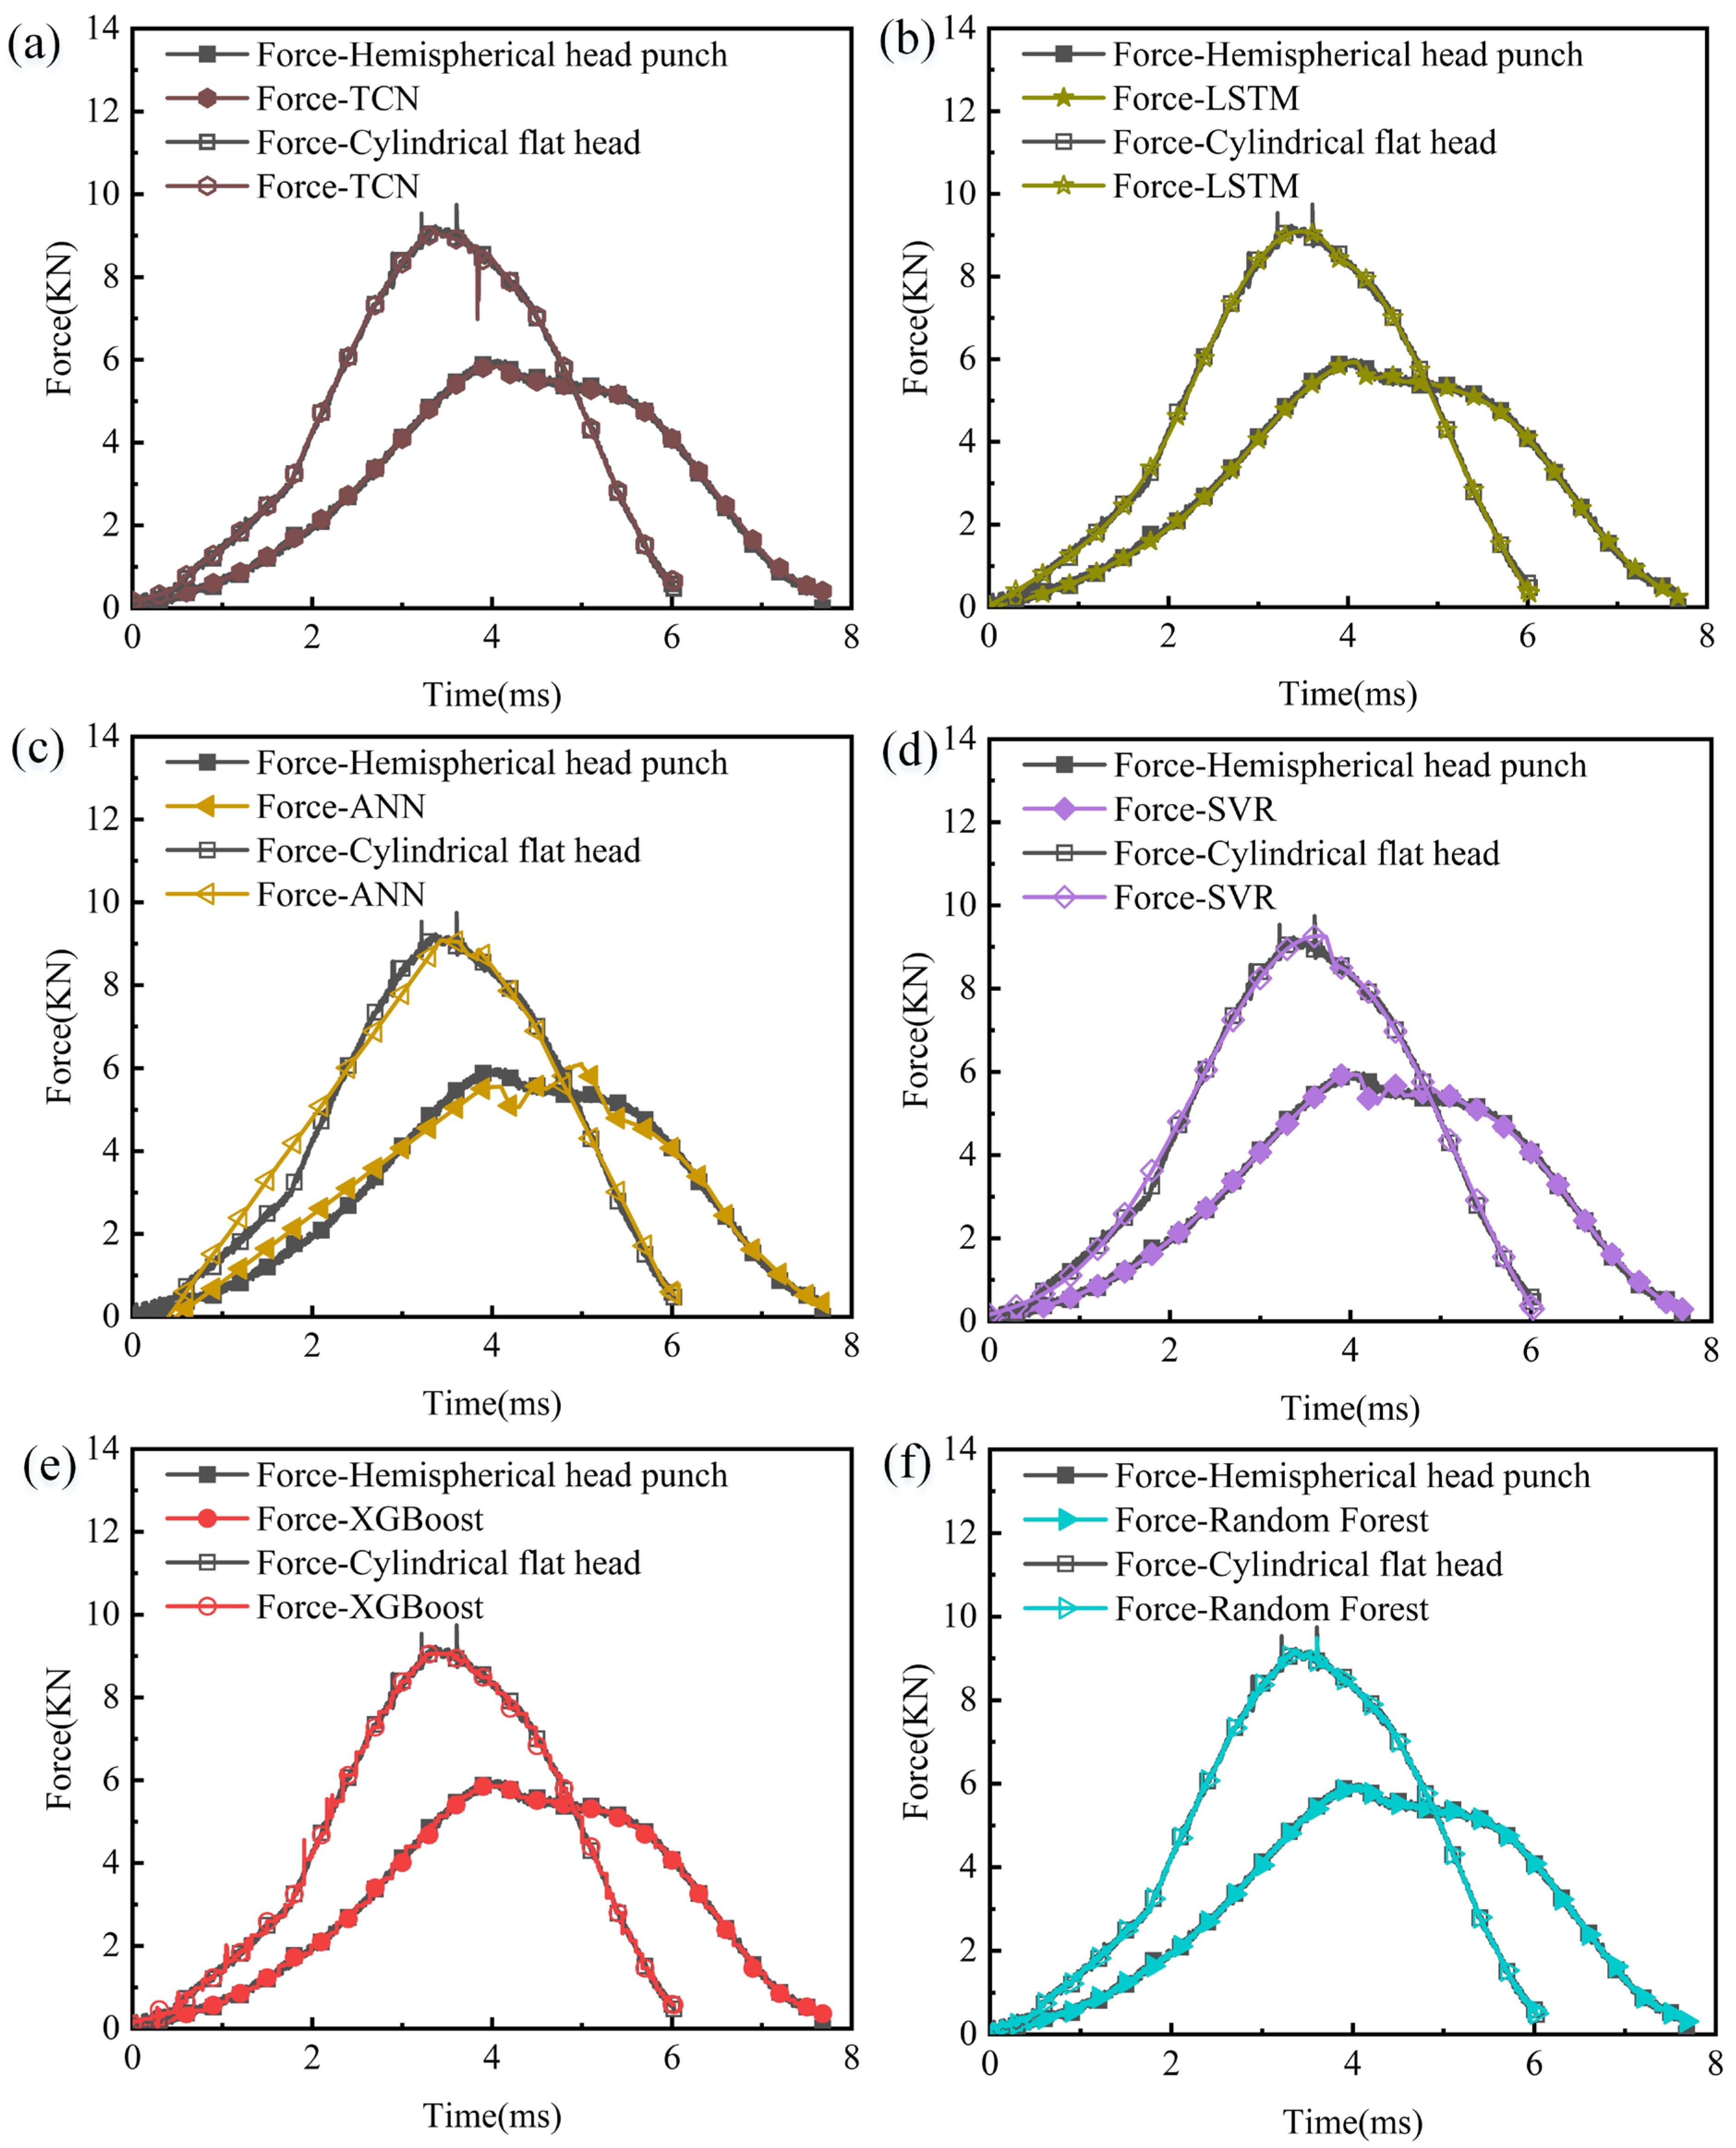
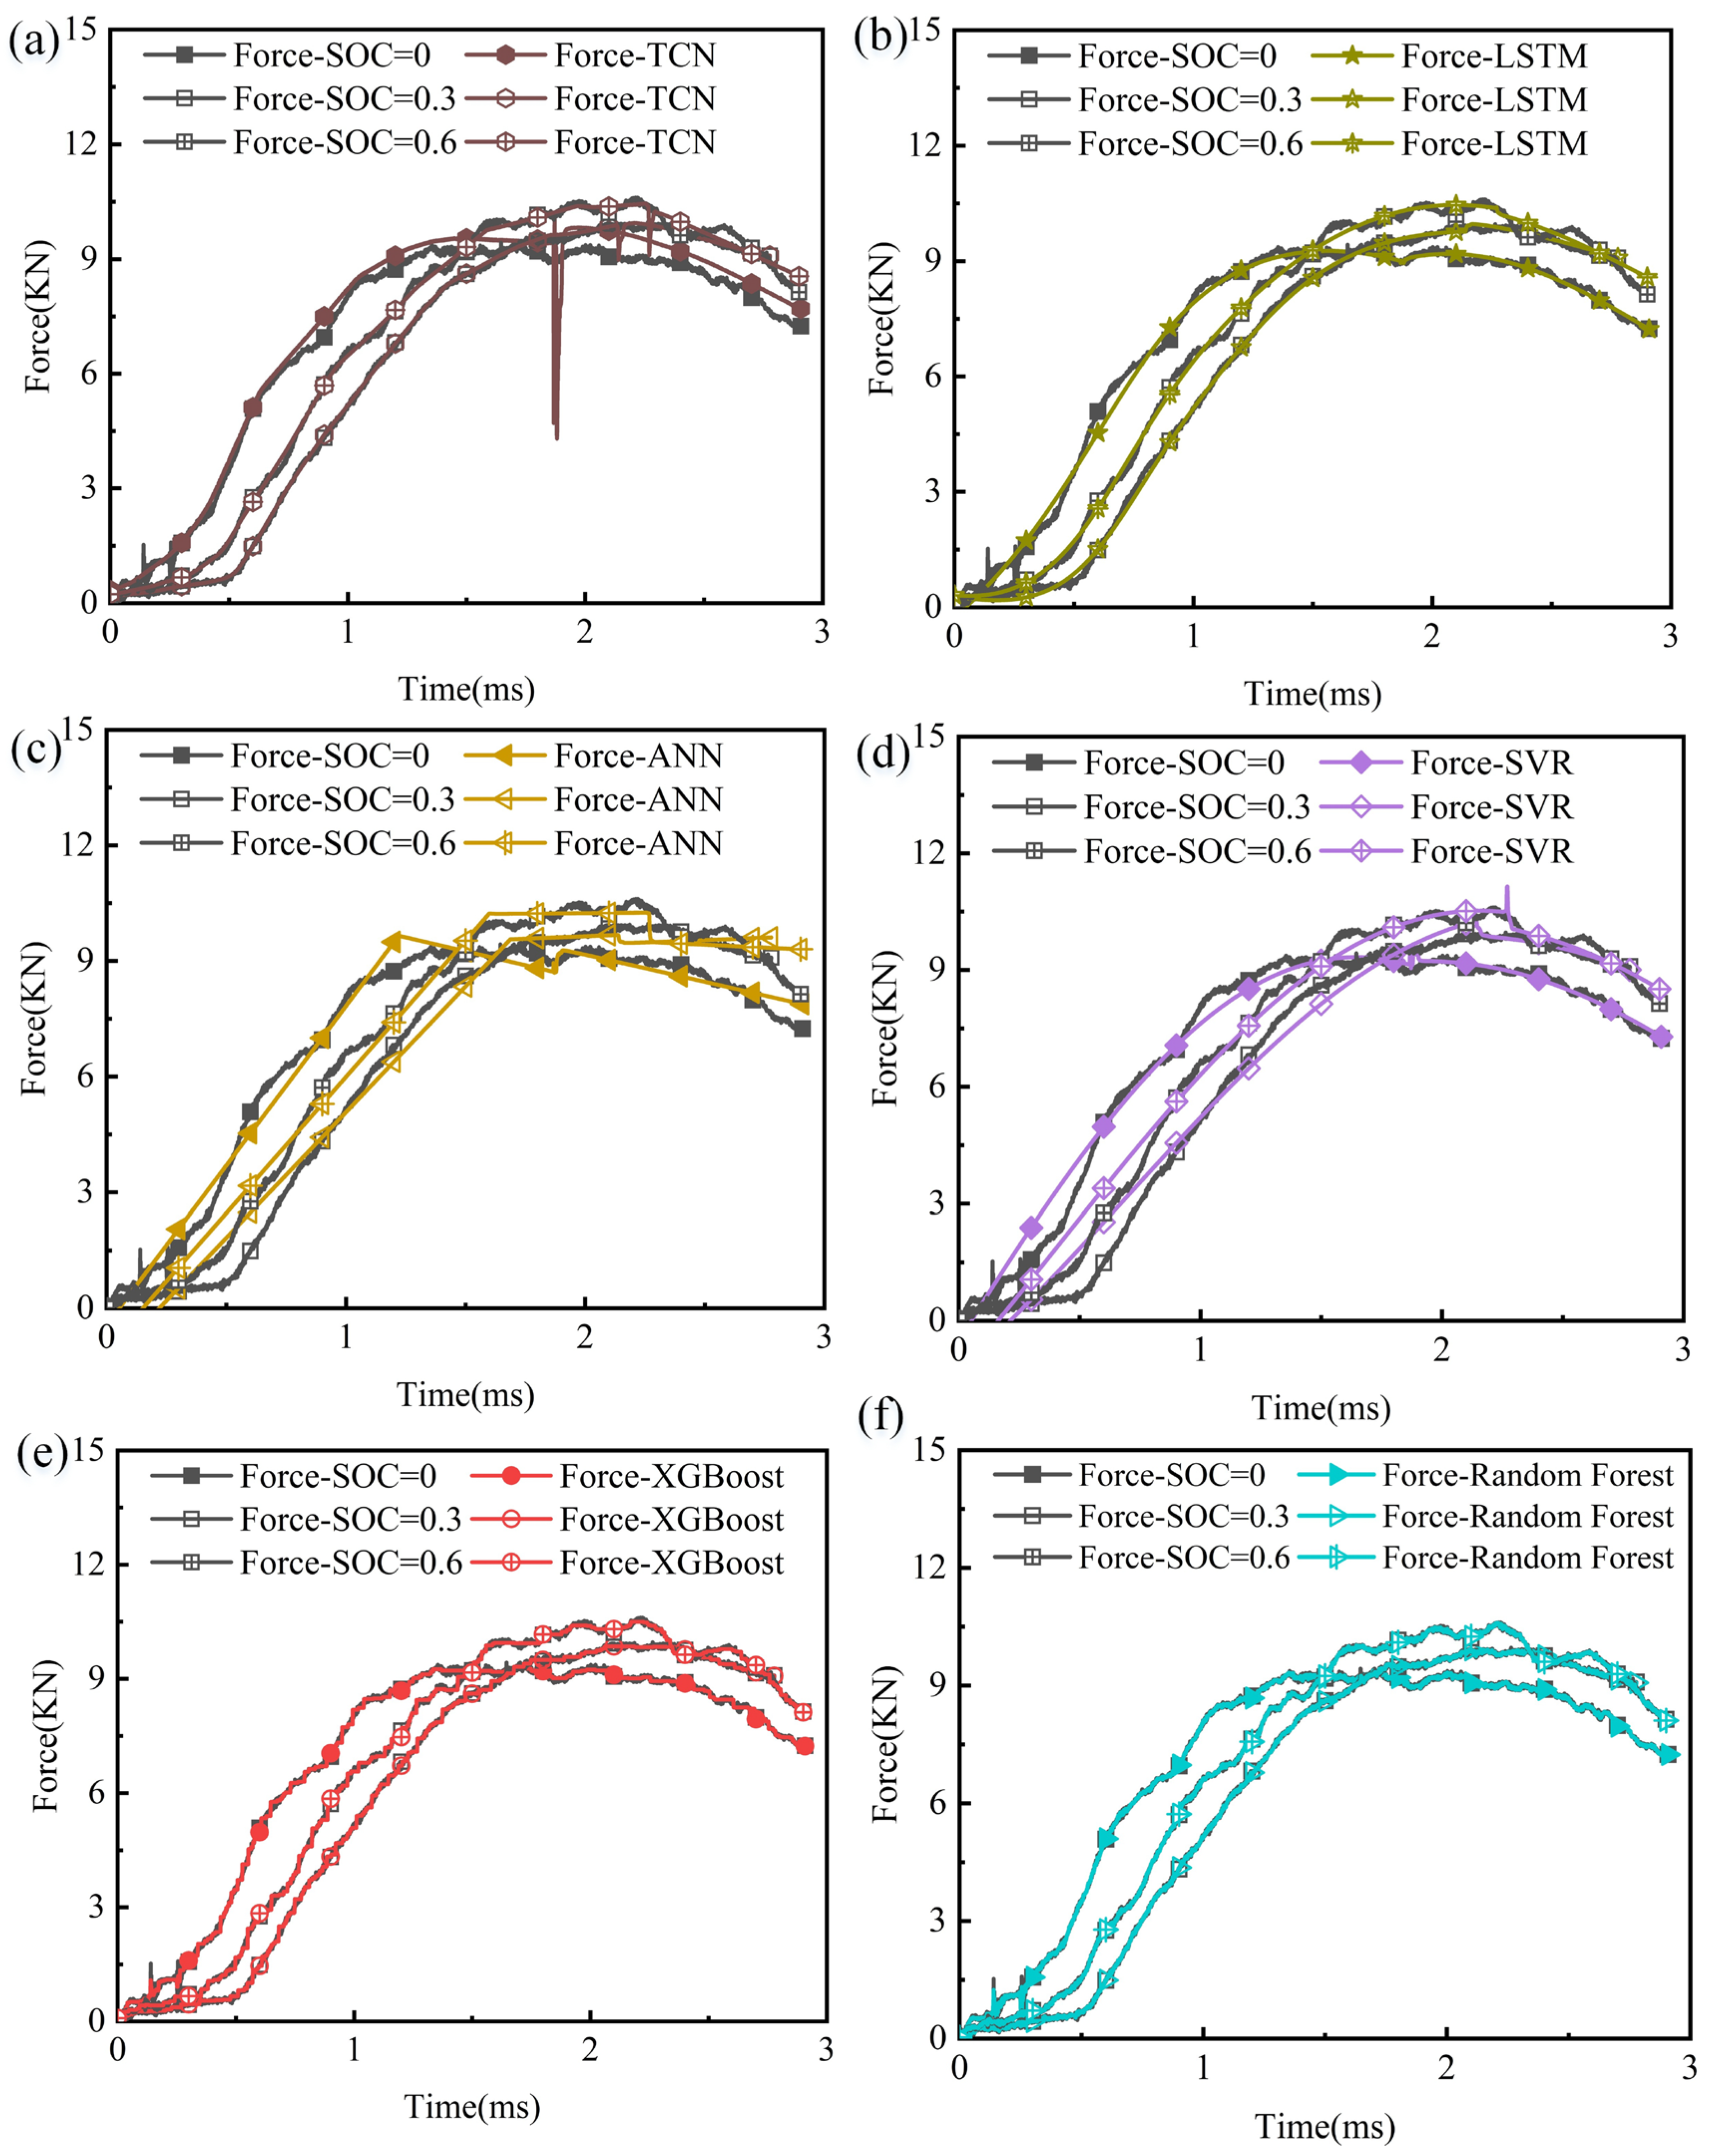
Figure 4a–f present the impact force predictions of six ML models for cylindrical LIBs under different indenter conditions. As shown in Figure 4c,d, both the ANN and SVR models achieved R2 values above 0.95. The ANN model reproduced the overall mechanical trend but underestimated the PF, while the SVR model fitted the general pattern well yet failed to capture local nonlinear oscillations.
Figure 4a,b,e,f display the predictions from the TCN, LSTM, XGBoost, and RF models, respectively. All four models accurately predicted the PF and the overall force–time trajectory, while the failure-related stage was identified using the voltage-drop criterion as defined in Section 4.1. Notably, the ensemble tree-based models (XGBoost and RF) exhibited the highest reconstruction fidelity under high-frequency impact signals, with predicted force–time curves almost identical to the experimental data. In contrast, the temporal models (TCN and LSTM) effectively captured time dependencies but displayed slightly larger local deviations in oscillatory segments.
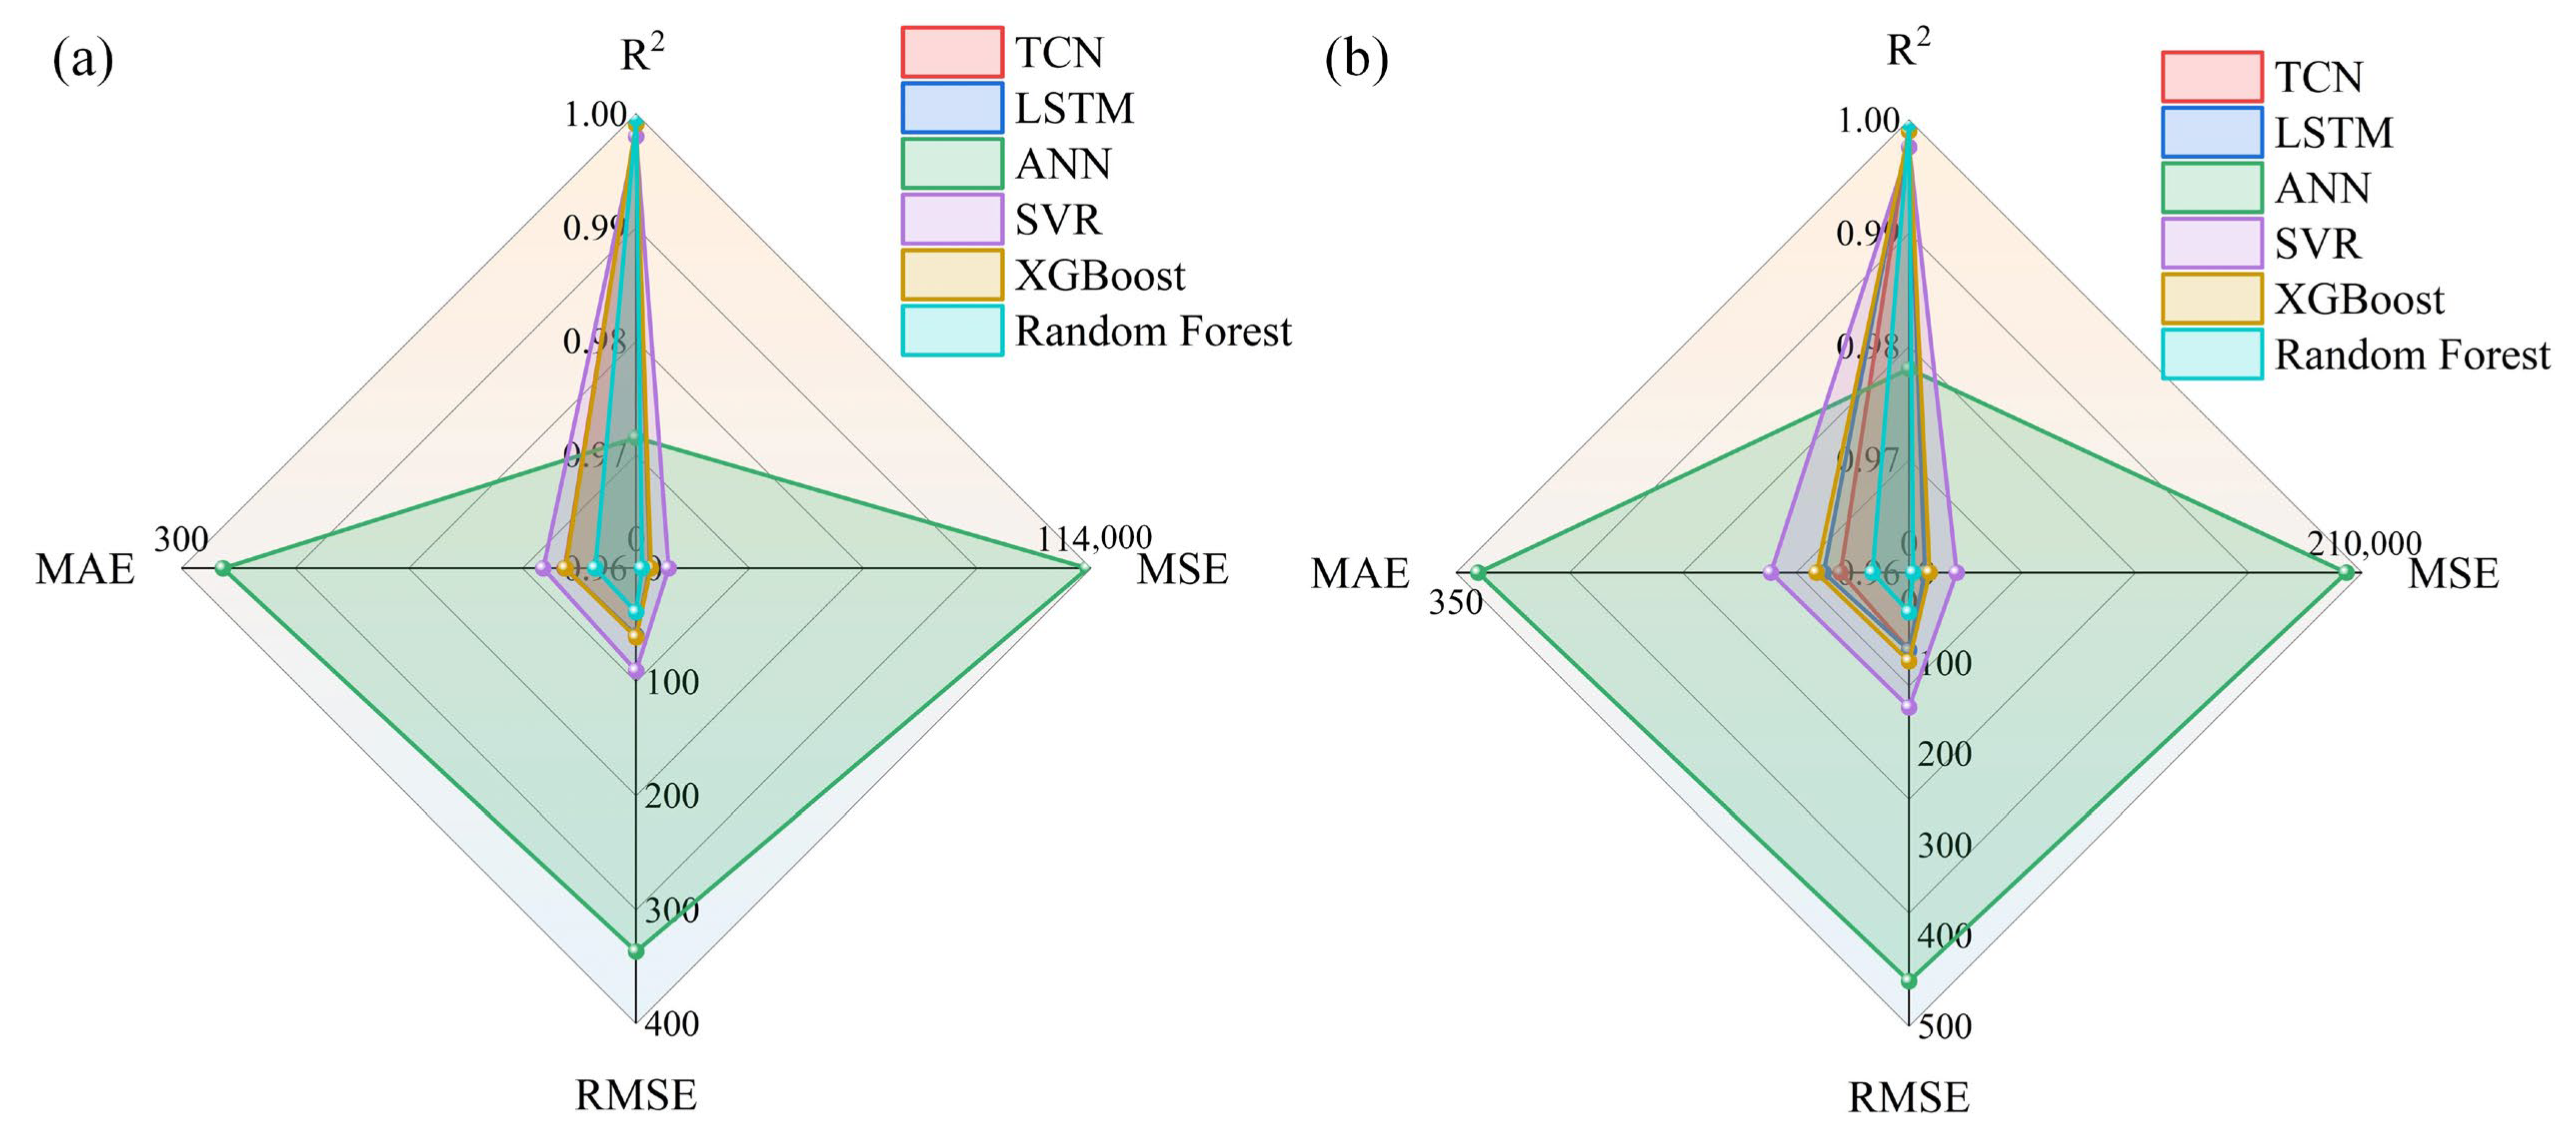
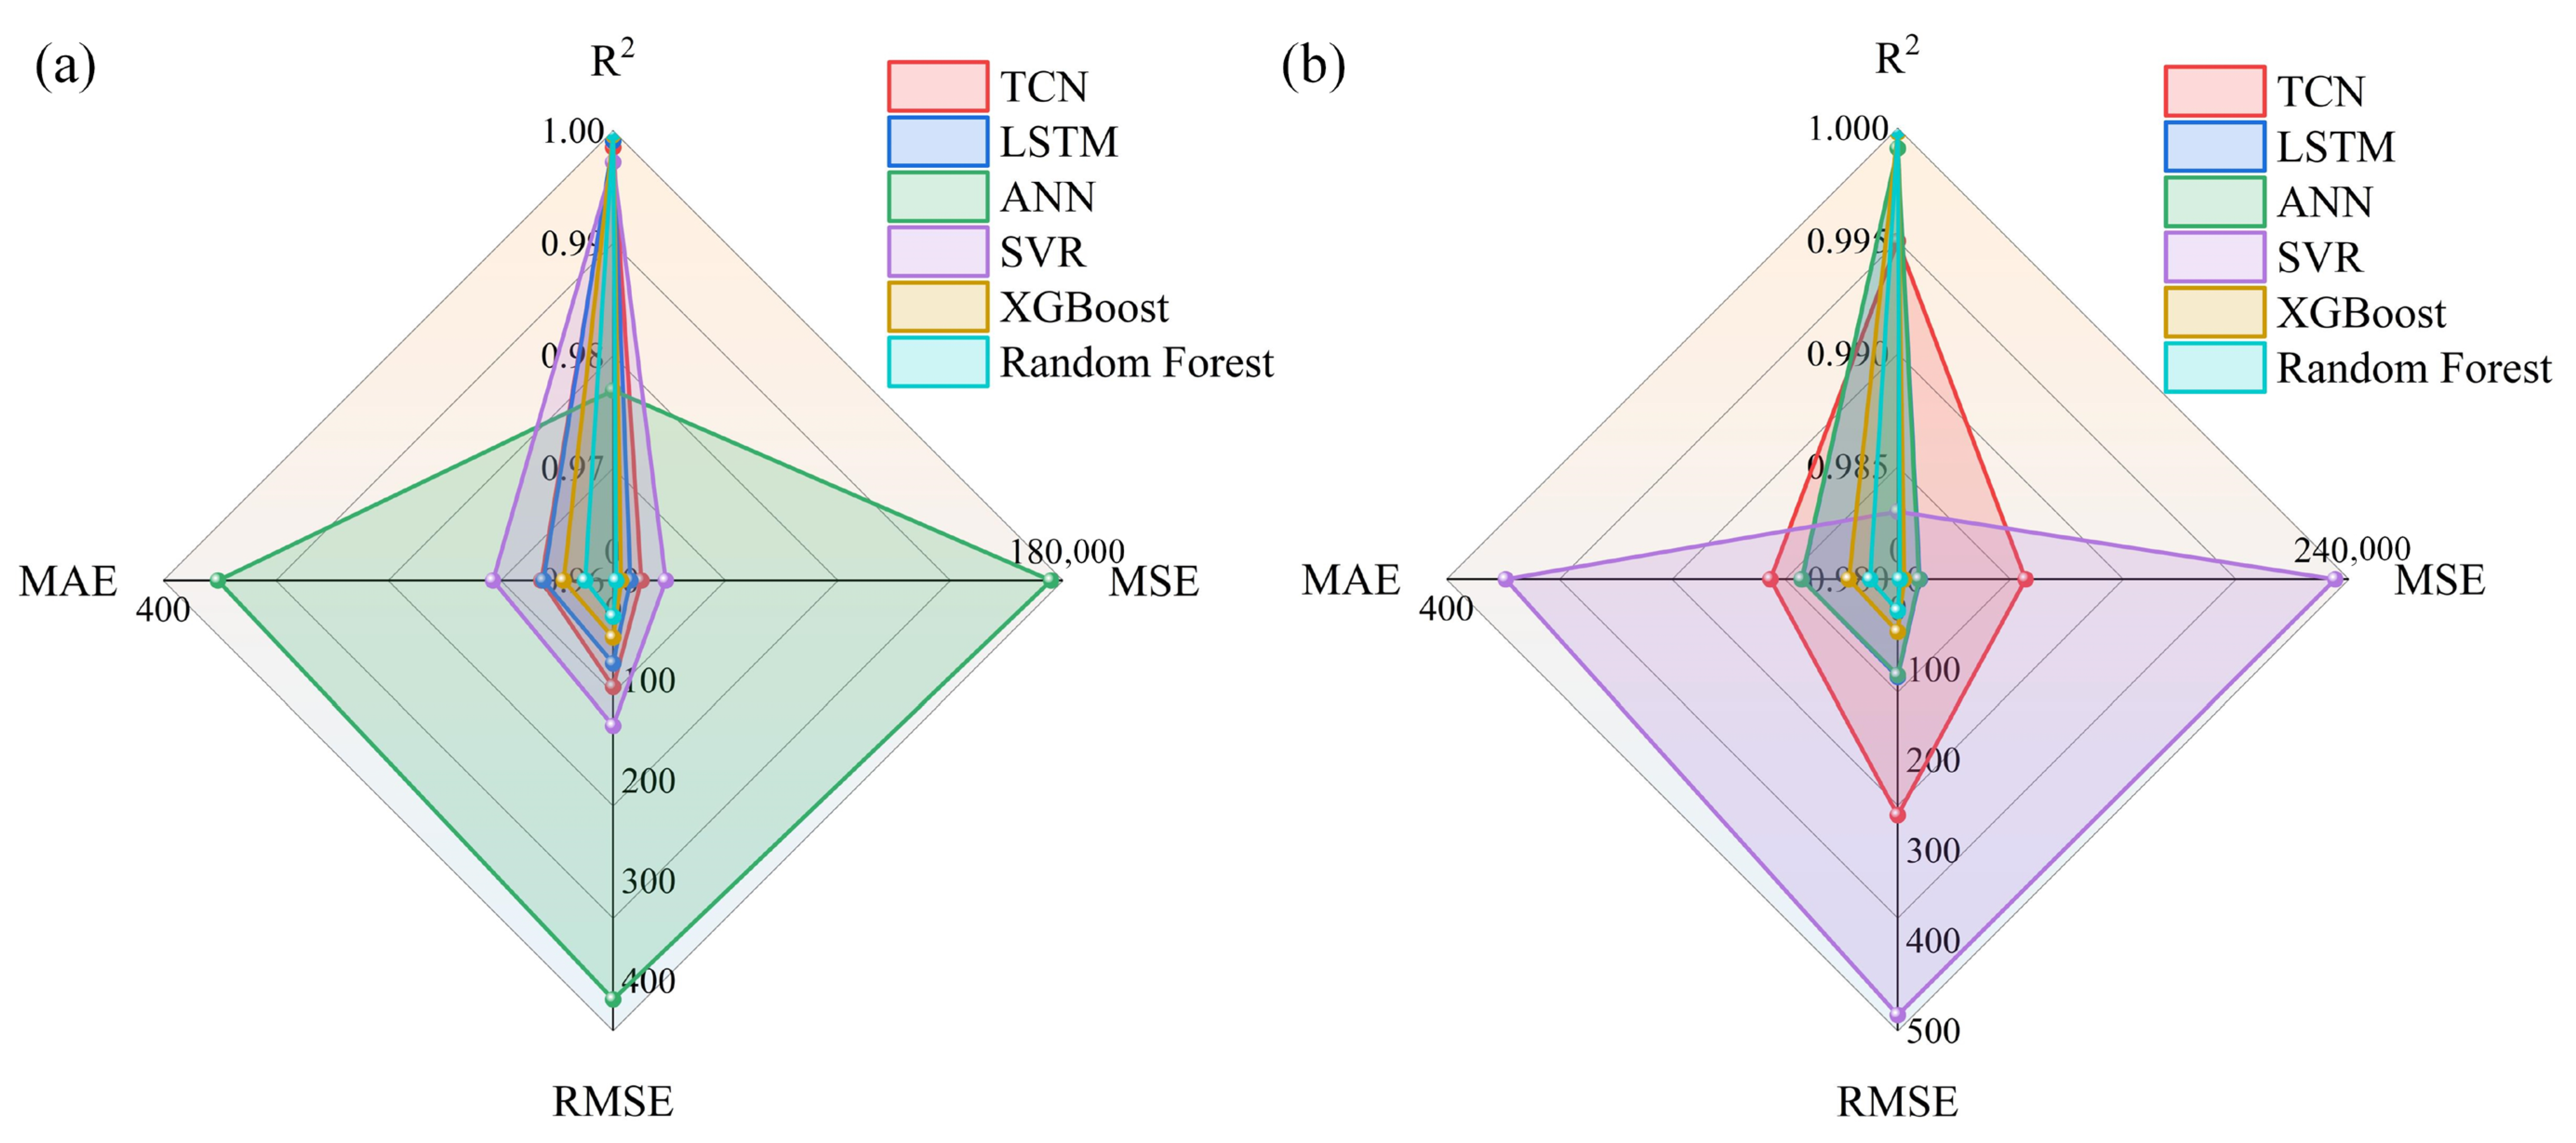
Figure 5a,b summarize the overall metrics under hemispherical and flat indenter conditions. The tree-based models (XGBoost and RF) achieved the best performance, with R2 values exceeding 0.999 and the smallest RMSE and MAE, confirming their superior accuracy under the present experimental setup. The temporal models (TCN and LSTM) ranked second, accurately reproducing dynamic variations, whereas traditional models (SVR and ANN) yielded lower precision, making them more suitable for general trend analysis or preliminary feature identification. It should be noted that such high R2 values mainly indicate high-fidelity reconstruction of force–time trajectories within the same experimental domain, rather than strict generalization to unseen impact events.
These differences arise from the intrinsic nature of the dynamic failure data, which exhibit high dimensionality and strong nonlinearity. Tree-based models possess inherent advantages in learning complex, non-smooth relationships and maintaining feature interactions, thus offering better stability and prediction performance under the present experimental setup for force–time response prediction.

4.1.2. Prediction Under Repeated Loading Conditions

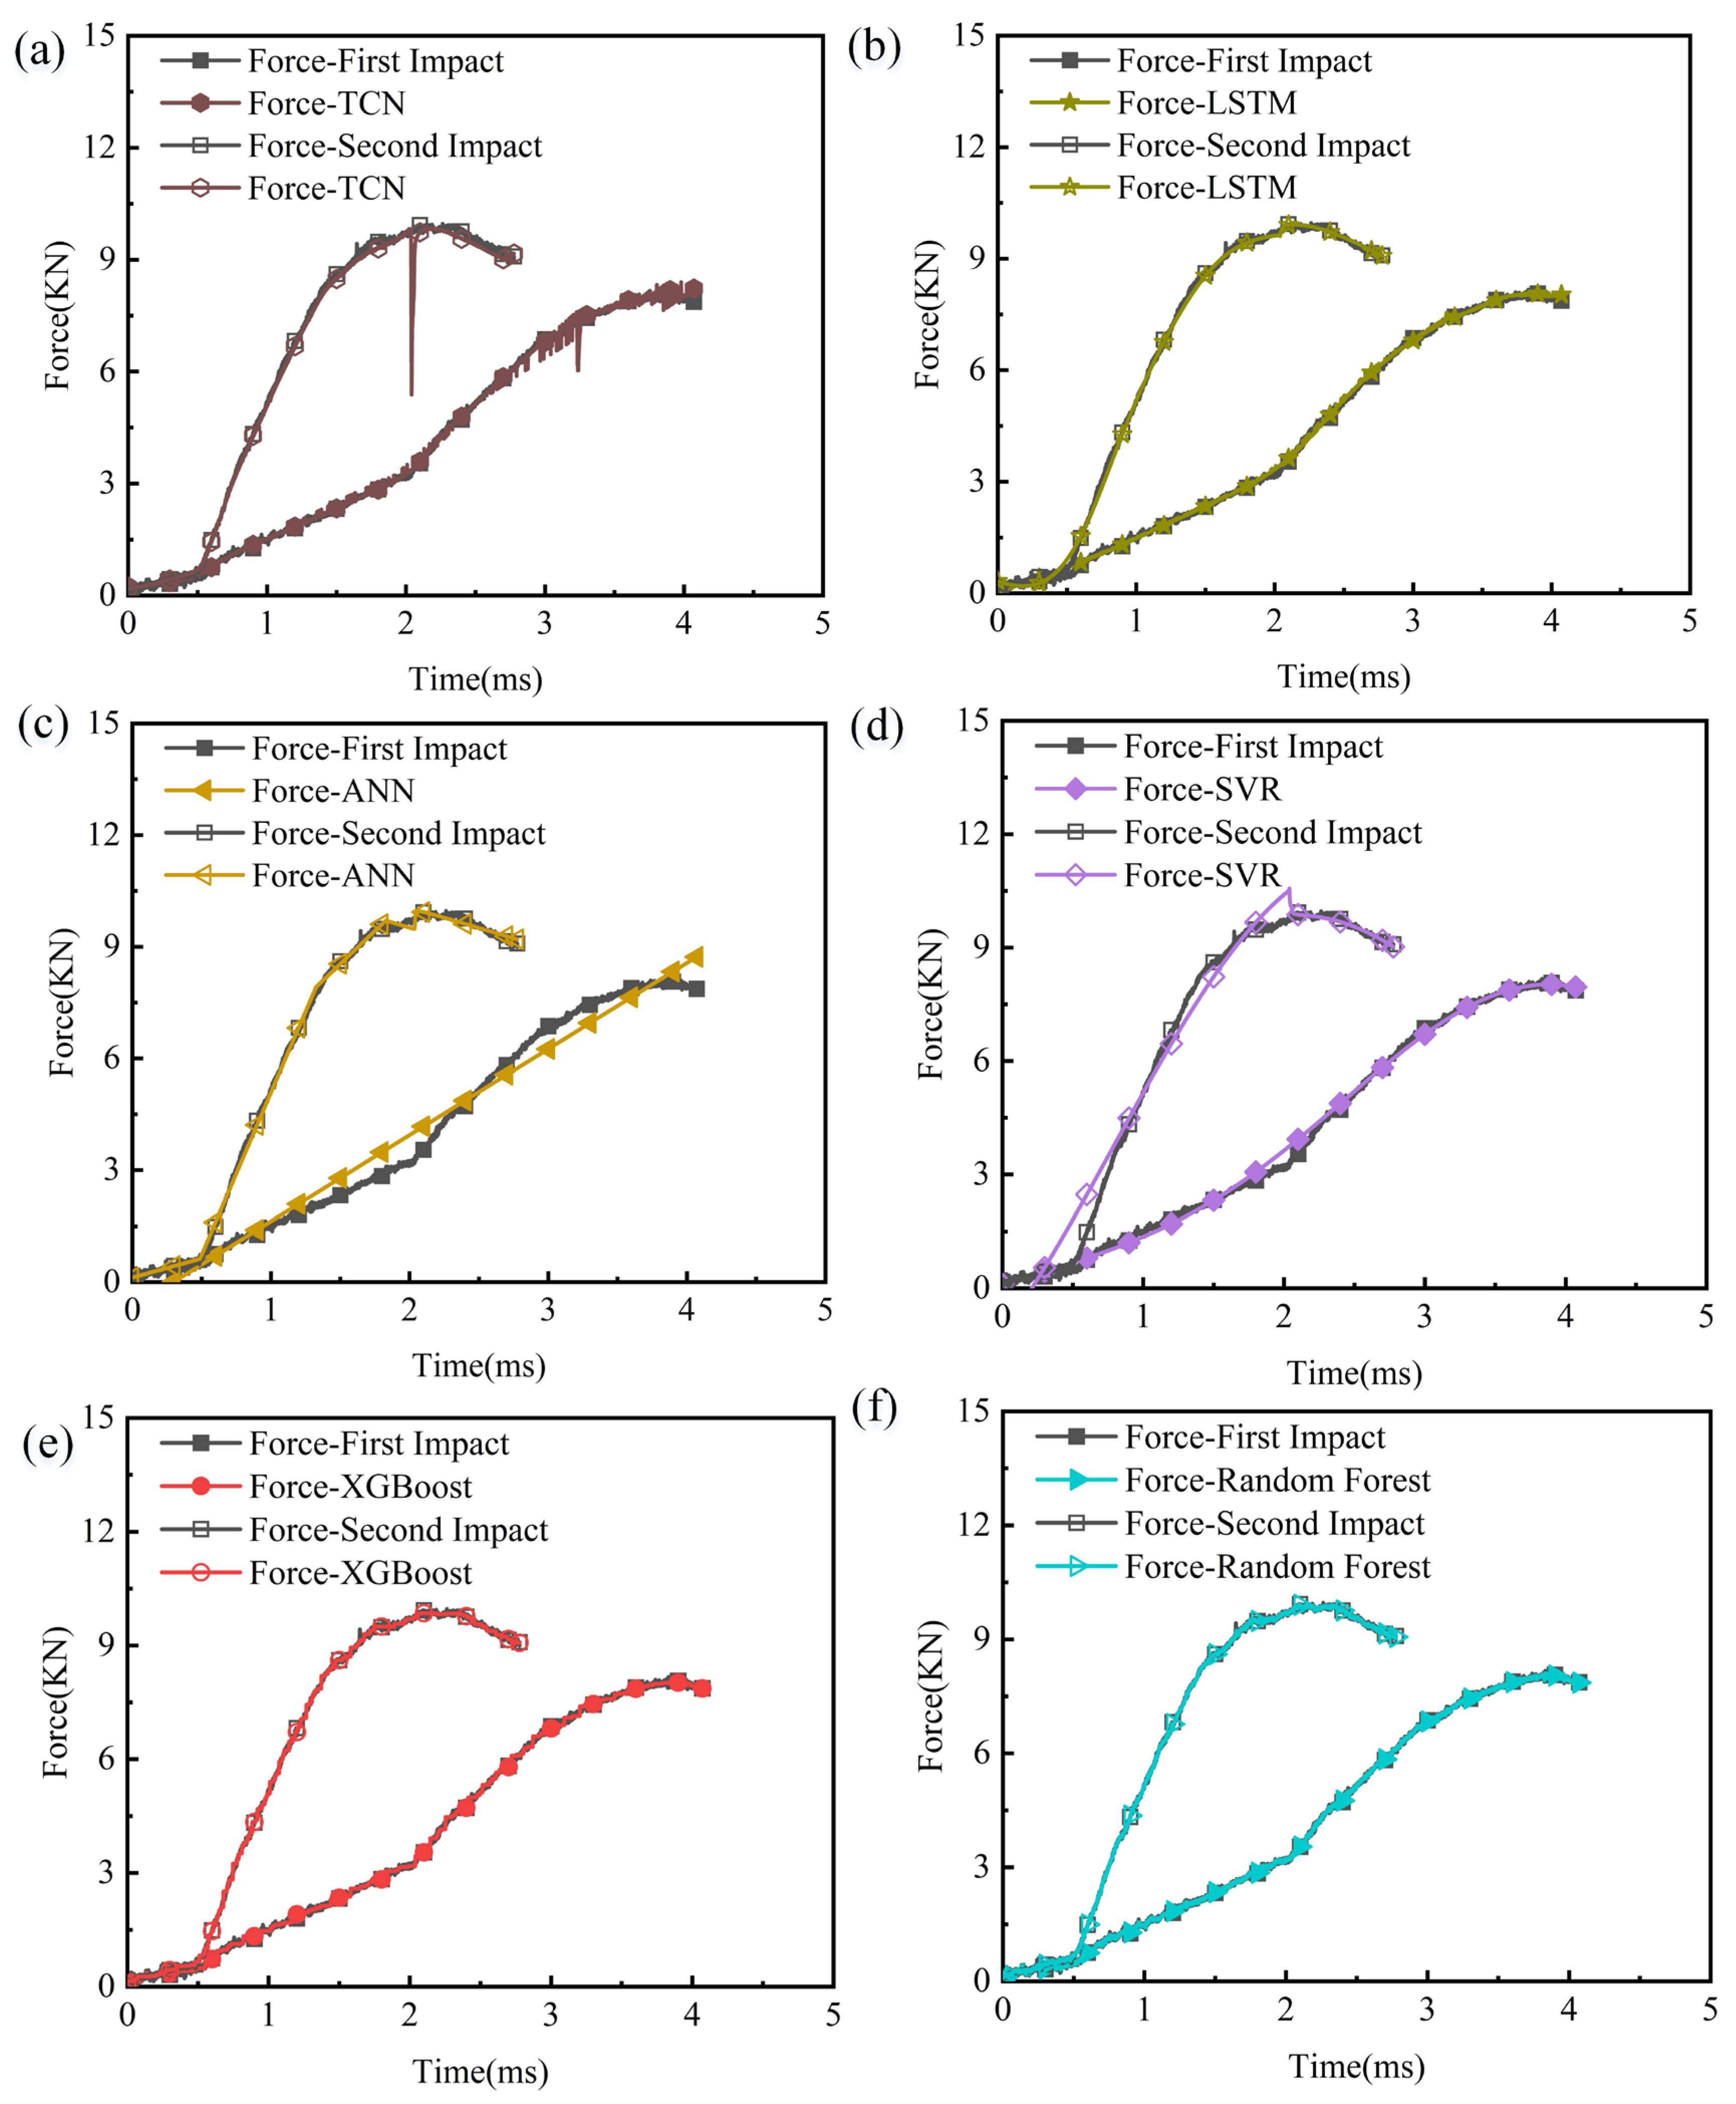
Figure 6a–f show the force prediction results of six ML models for cylindrical LIBs under repeated loading conditions. The TCN model achieved good overall fitting performance, as shown in Figure 6a, with an R2 value above 0.99, successfully reproducing the mechanical responses of both the first and second impacts, though minor deviations appeared in oscillatory segments. The ANN and SVR models, as shown in Figure 6c,d, captured the general response trends but showed relatively low accuracy and limited sensitivity to variations between successive impacts, limiting their applicability to nonlinear multi-impact prediction.
Figure 6b,e,f display the results of the LSTM, XGBoost, and RF models. All three achieved exceptional accuracy in predicting the force–time trajectories and PF, with R2 values exceeding 0.999. Their predicted force–time curves nearly overlapped with the experimental data. The LSTM model effectively captured temporal evolution patterns, making it suitable for continuous impact sequences, while the two tree-based models (XGBoost and RF) exhibited high reconstruction fidelity in oscillatory and peak regions, yielding minimal local errors and precisely reconstructing the complex dynamic responses.
Figure 7a,b compare the model performance metrics for the first and second impacts. The LSTM, XGBoost, and RF models consistently delivered the best overall results, maintaining R2 values above 0.999 and the lowest RMSE and MAE values. Among them, the RF model demonstrated the smallest prediction errors across the repeated impacts. In comparison, the TCN model preserved the overall pattern but showed small deviations due to local oscillations, whereas the ANN and SVR models experienced noticeable accuracy degradation during the second impact, with R2 dropping to approximately 0.97, indicating limited prediction performance under the present experimental setup.
Overall, both ensemble learning and temporal models demonstrated strong prediction performance for nonlinear dynamic features under repeated impacts. The superior performance of the tree-based models is attributable to their ability to capture complex nonlinear relationships among the input variables, resulting in high-precision force–time response prediction under the present experimental setup.

4.1.3. Prediction Under Different SOC Conditions

Figure 8a–f present the force prediction results of six ML models for cylindrical LIBs under different SOC levels. The TCN model, shown in Figure 8a, accurately reproduced the overall mechanical response across all SOC, achieving an R2 value above 0.99, though slight deviations appeared in oscillatory segments. The ANN and SVR models, as shown in Figure 8c,d, captured the general force–time trends with R2 values between 0.98 and 0.99, but underestimated the PF and failed to describe abrupt nonlinear transitions during strain localization.
The LSTM, XGBoost, and RF models, as shown in Figure 8b,e,f, achieved excellent agreement with experimental data, with R2 values exceeding 0.999. The LSTM model effectively learned temporal dependencies and characterized the coupled force–voltage evolution during impact. The ensemble models (XGBoost and RF) showed superior reconstruction fidelity in peak-force regions and captured oscillatory variations with smaller local deviations, enabling precise reconstruction of the force–time response under varying SOC conditions.
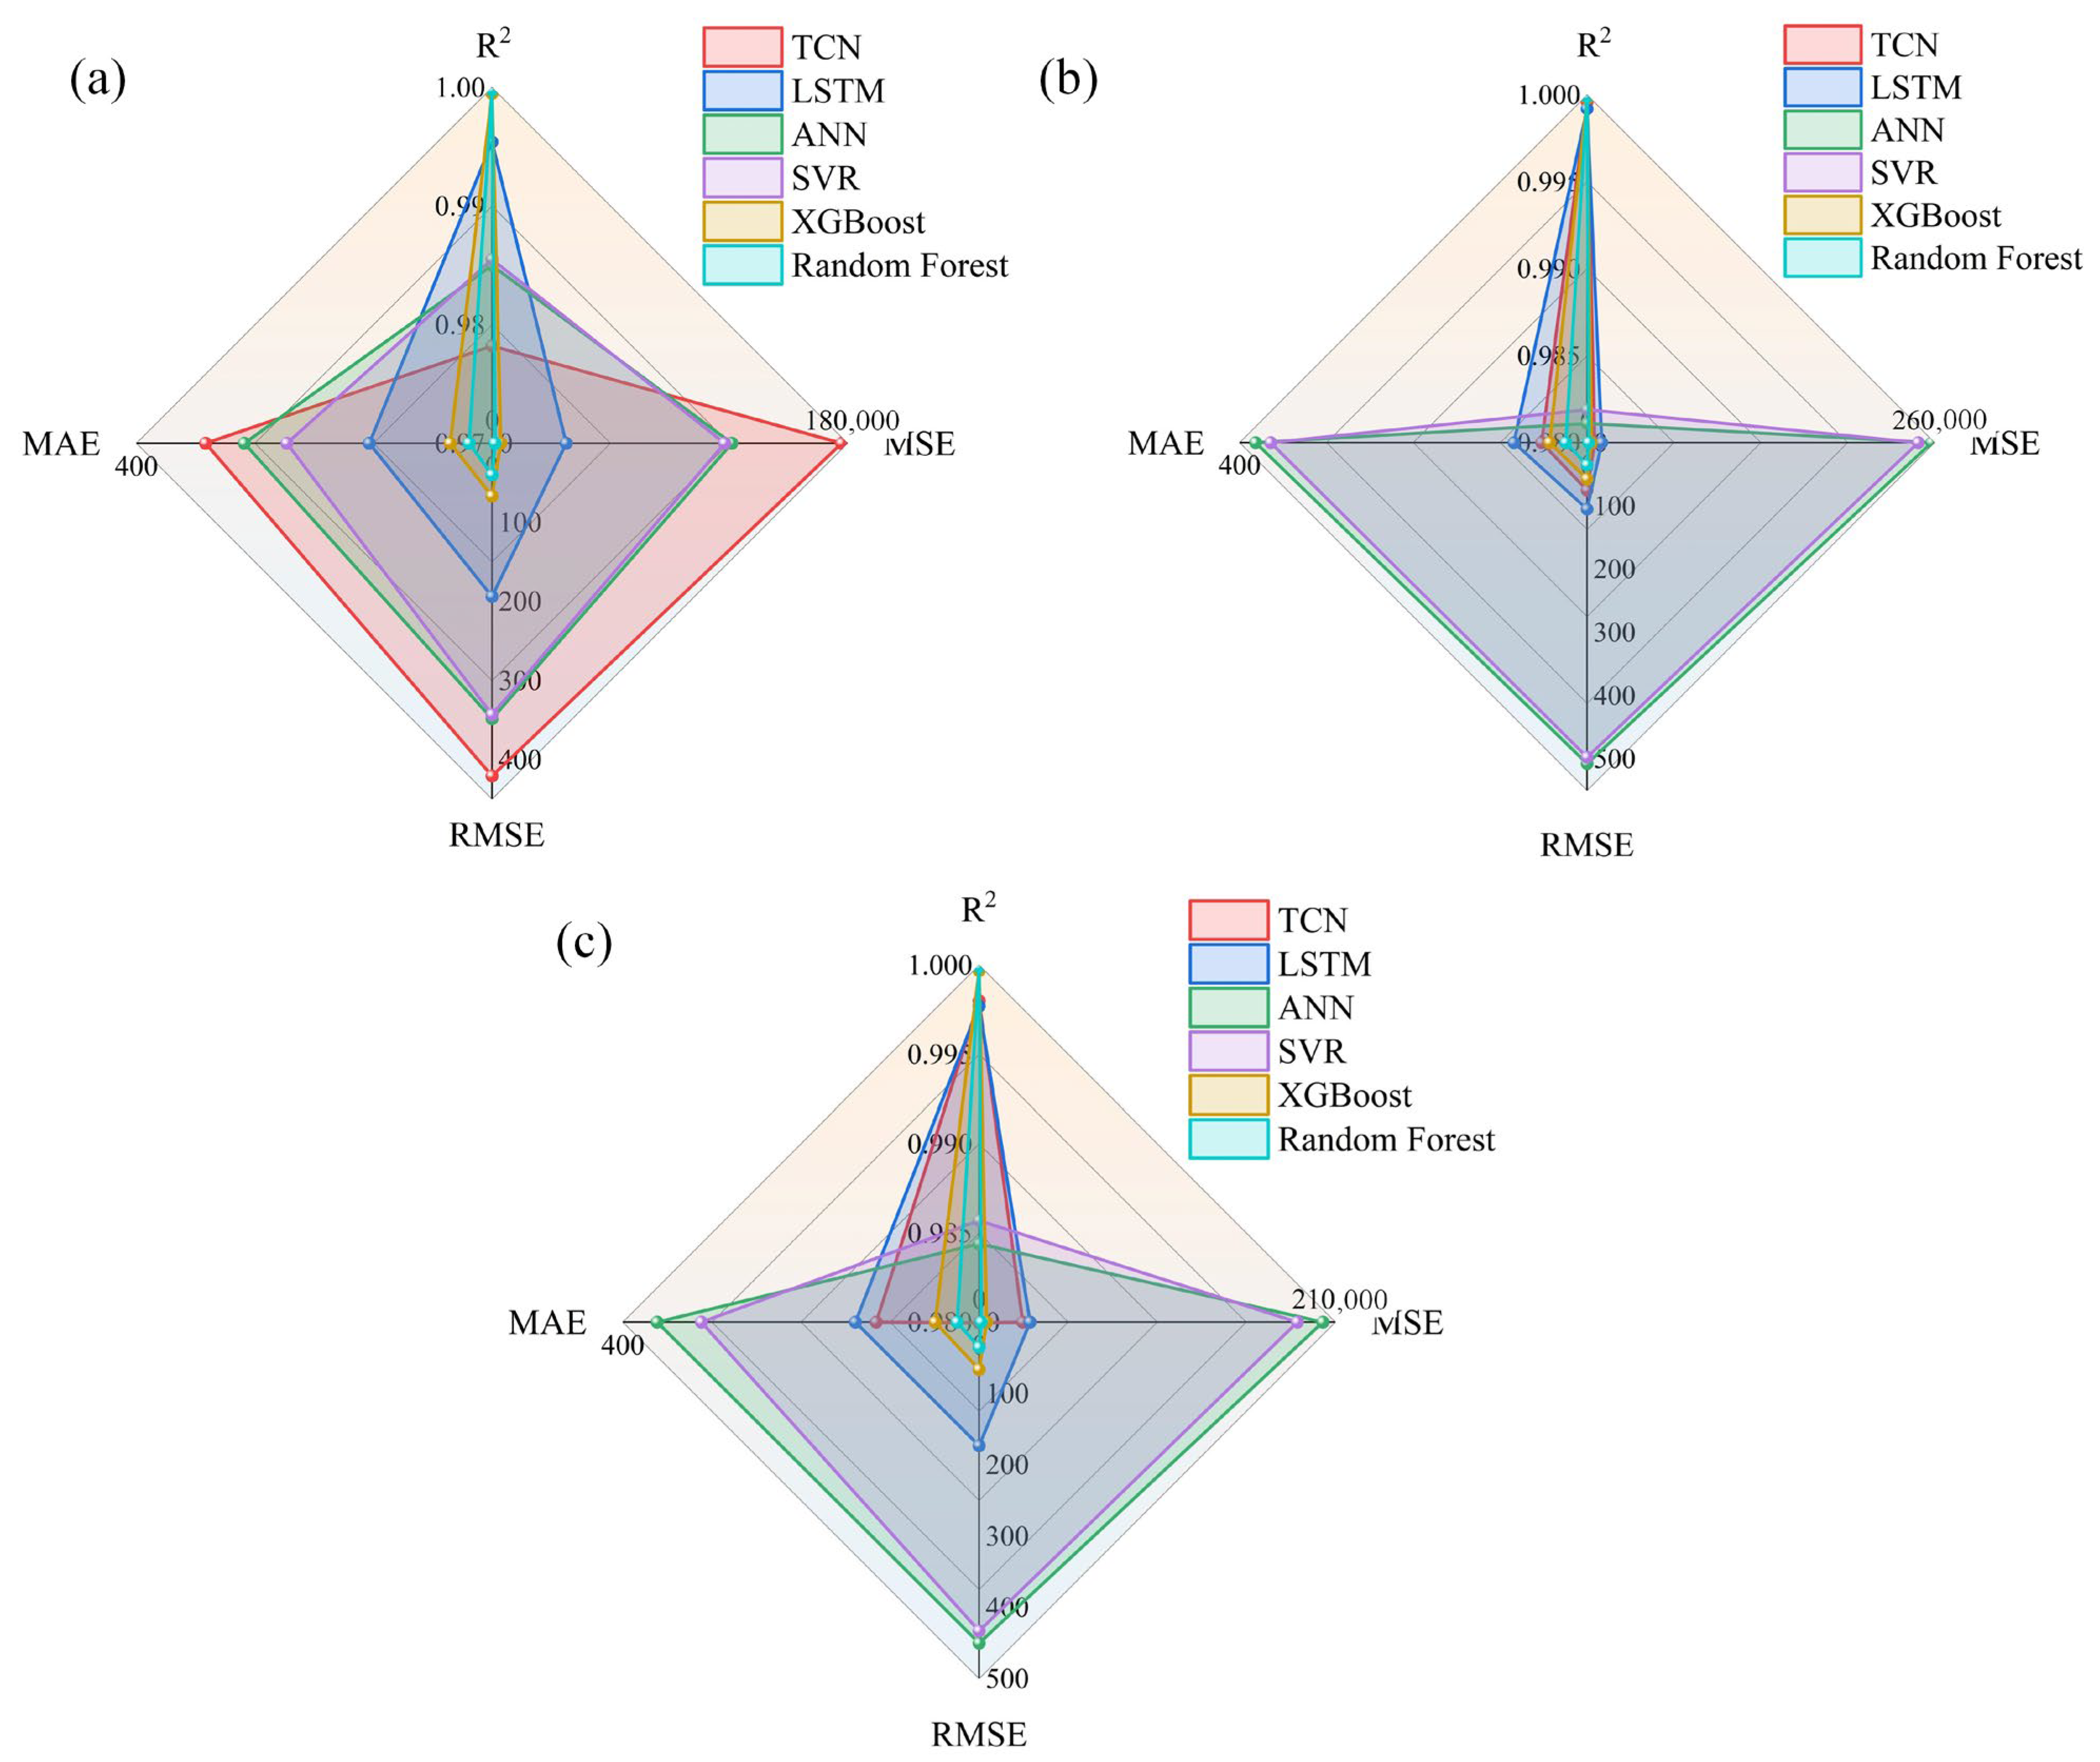
Figure 9a–c summarize the model performance metrics at SOC of 0%, 30%, and 60%. The LSTM, XGBoost, and RF models consistently achieved the highest accuracy across all conditions. Among them, the RF model maintained the most stable performance, with an average R2 of approximately 0.9996 and the smallest RMSE and MAE values, indicating outstanding prediction performance under the present experimental setup. The TCN model performed comparably to the ensemble methods at low SOC but exhibited reduced stability as SOC increased. In contrast, the ANN and SVR models showed larger prediction errors at higher SOC, confirming their limited capability to represent highly nonlinear mechanical behavior at higher SOC.
Overall, increasing SOC led to higher PFs and a narrower deformation window, reflecting state-dependent stiffness and deformability under the tested conditions. Both ensemble learning and temporal models effectively captured this nonlinear correlation, demonstrating high prediction accuracy under the present experimental setup across different SOC conditions.

4.2. Performance Comparison and Analysis

A comprehensive comparison of the prediction results under various loading conditions revealed distinct differences in accuracy and stability among the models. The ensemble learning methods—XGBoost and RF—achieved the best overall performance, with R2 values above 0.999 and the lowest RMSE and MAE, demonstrating excellent stability under the present experimental setup. The temporal models—LSTM and TCN—accurately captured temporal correlations and the nonlinear evolution of the signals, achieving strong fitting performance under low SOC and single-impact conditions. However, both models showed slightly larger local deviations in oscillatory segments, which contributed to minor mismatches in oscillatory portions of the predicted curves. In contrast, the traditional regression approaches—SVR and ANN—displayed comparatively lower accuracy, with R2 values below 0.99. Although they reproduced the overall trend of the force–time response conditioned on voltage, they were unable to represent the pronounced non-linearity and complex oscillatory behavior associated with dynamic impact processes.
Overall, both ensemble and temporal models demonstrated superior predictive accuracy and prediction performance under the present experimental setup for multi-condition dynamic impact analysis. They effectively characterized the nonlinear mechanical behavior of cylindrical LIBs, supporting impact-response assessment and impact-response prediction with failure indication. With increasing SOC, the stiffness of the electrode materials increased and internal stresses accumulated, resulting in higher and more concentrated force peaks. Ensemble learning models achieved better fitting accuracy in such strongly coupled nonlinear scenarios due to multi-feature splitting and hierarchical learning, whereas the LSTM model, although capable of capturing temporal dependencies, remained less responsive to static operational parameters.
It should be noted that the extremely high R2 values should be interpreted primarily as reconstruction accuracy for densely sampled force–time trajectories under the present experimental setup. Since the training/testing split was performed at the time-point level and time was included as an input feature, temporal correlation may lead to optimistic estimates and interpolation-like performance. Strict assessment of generalization to unseen impact events requires event-level splitting and additional independent tests, which will be addressed in future work.
Although the proposed ML models achieved high accuracy under controlled laboratory conditions, their applicability should be interpreted within the present experimental setup and data-acquisition protocol. Real-world impact scenarios may involve additional uncertainties, such as structural vibration, multi-directional loading, and sensor noise, which could affect prediction reliability. In practice, the trained models can be used to rapidly estimate force–time responses from measured voltage and loading parameters, which is useful for early-stage safety screening when repeated drop tests or computationally expensive simulations are not feasible. The predicted force trajectory, together with the voltage-drop-based failure indication, enables practical comparison of how indenter geometry, SOC, and repeated impacts influence peak force and failure-related characteristics. Once trained, the models enable rapid, low-cost inference, but performance depends on signal quality and acquisition consistency. Therefore, further validation across different cell batches and operating environments is needed before large-scale industrial application.

4.3. Input Variable Roles and Physical Interpretation

To connect the ML results with physical mechanisms, the roles of input variables were discussed with emphasis on the ensemble models RF and XGBoost. A mechanistic interpretation is provided to explain how each input variable is expected to influence force prediction. In general, time serves as an impact-stage descriptor within an event, voltage reflects the coupled electromechanical evolution and failure-related voltage-drop behavior during loading, and impact-condition parameters, including indenter geometry, SOC, and repeated impacts, modulate contact conditions, stiffness and deformability, and damage accumulation. This interpretation helps link model inputs to known impact response and ISC-related mechanisms without claiming a numerical importance comparison.
The influence of indenter geometry is physically associated with changes in contact area evolution and stress concentration, which shifts peak force and alters the post-peak response. The influence of SOC is consistent with higher peak force and a reduced deformation window at higher SOC under the tested conditions. The influence of repeated impacts is consistent with cumulative internal damage that promotes earlier voltage collapse in the second strike. These interpretations help link the data-driven predictions to known impact and internal short-circuit mechanisms.
Formal uncertainty quantification was not included in the current scope. Prediction reliability is expected to be sensitive to experimental signal quality, including measurement noise, sensor bandwidth limitations, mounting stiffness, and sampling consistency. Under the present setup, all tests were conducted using the same equipment and acquisition settings, which reduces systematic variability and supports stable model comparison. Uncertainty-aware extensions will be explored in future work, for example, by using variability across ensemble members or repeated training runs as confidence proxies, together with robustness evaluation under degraded signal conditions.
The present study was conducted using NCR18650B cylindrical lithium-ion cells under a controlled laboratory drop-weight impact setup, and the results are therefore validated within this specific cell format and chemistry. Application to other battery formats or chemistries may be constrained by differences in casing structure, internal architecture, electrode materials, and state-dependent mechanical behavior, which can alter both force–time trajectories and voltage-drop characteristics under impact. Additional datasets and validation, and potentially model retraining, will be required to ensure reliable performance when extending the framework to other cell types such as prismatic or pouch designs.

5. Conclusions

This study systematically investigated the mechanical failure behavior of cylindrical LIBs under dynamic impact loading by integrating experimental analysis with ML techniques. Dynamic response characterization and model evaluation were performed under multiple loading conditions. The main conclusions are summarized as follows:
  • The load path was governed by indenter geometry, and the resulting contact condition and stress concentration were altered, thereby changing the peak force and the failure-related response. Under the tested conditions, the flat indenter produced a higher peak force than the hemispherical indenter, indicating a stronger mechanical response associated with the different contact morphology.
  • Damage accumulation under repeated impacts was reflected by changes in the failure-related response. Compared with the first strike, the second strike exhibited earlier voltage collapse and a reduced apparent safety margin under the tested repeated-impact condition.
  • SOC significantly influenced the mechanical response under impact. With increasing SOC, the peak force increased and the deformation window became narrower under the tested conditions, while the voltage-drop onset tended to occur later within the impact event. At lower SOC, gentler force responses and a wider deformation window were observed.
  • Six representative ML models, ANN, SVR, LSTM, TCN, RF, and XGBoost, were constructed based on experimental data, and their prediction performance was systematically evaluated under different conditions. The highest prediction accuracy with R2 above 0.999 under the present experimental setup was achieved by the ensemble learning models (XGBoost and RF), demonstrating superior reconstruction performance compared with conventional approaches. Nonlinear and time-dependent features of dynamic impact responses were effectively captured by the temporal models (LSTM and TCN).

Author Contributions

B.L.: Conceptualization, Methodology, Resources, Writing—original draft. Y.Z.: Conceptualization, Data curation, Formal analysis, Methodology, Software, Writing—original draft. X.Z. (Xuehui Zhou): Formal analysis, Funding acquisition, Writing—review & editing. Z.H.: Formal analysis, Writing—review & editing. X.Z. (Xinchun Zhang): Writing—review & editing, Methodology. All authors have read and agreed to the published version of the manuscript.

Funding

This work was supported by the Key R & D Program of Guangxi Science and Technology Plan Project (AB25069352), Research Foundation Ability Enhancement Project for Middle-aged and Young Teachers in Guangxi Universities (2025KY1553) and Hebei Province Graduate Innovation Funding Project (Grant No.CXZZBS2026163).

Data Availability Statement

Data will be made available on request.

Conflicts of Interest

Author Bokui Li was employed by the Jiangsu Huadian Jurong Power Generation Co., Ltd. The remaining authors declare that the research was conducted in the absence of any commercial or financial relationships that could be construed as a potential conflict of interest.

References

  1. Zhang, X.C.; Zhang, T.; Liu, N.N.; Yin, X.D.; Wu, X.N.; Han, H.L.; Wang, Q.L.; Zhang, Y.J. Dynamic crushing behaviors and failure of cylindrical lithium-ion batteries subjected to impact loading. Eng. Fail. Anal. 2023, 154, 107653. [Google Scholar] [CrossRef] [Scilit]
  2. Chen, X.; Wang, T.; Zhang, Y.; Ji, H.; Ji, Y.; Yuan, Q. Dynamic mechanical behavior of prismatic lithium-ion battery upon impact. Int. J. Energy Res. 2019, 43, 7421–7432. [Google Scholar] [CrossRef] [Scilit]
  3. Li, J.; Wen, B.; Xie, Y.; Wen, H.; Cao, D.; Cai, C.; Wang, H. Failure analysis of effects of multiple impact conditions on cylindrical lithium-ion batteries. Engineering 2025, 6, 266. [Google Scholar] [CrossRef] [Scilit]
  4. Xu, P.; Li, J.; Lei, N.; Zhou, F.; Sun, C. An experimental study on the mechanical characteristics of li-ion battery during overcharge-induced thermal runaway. Int. J. Energy Res. 2021, 45, 19985–20000. [Google Scholar] [CrossRef] [Scilit]
  5. Zhang, X.C.; Gu, L.R.; Yin, X.D.; Huang, Z.X.; Ci, T.J.; Rao, L.X.; Wang, Q.L.; El-Rich, M. Mechanical behavior and performance under the present experimental setup of cylindrical lithium-ion batteries under mechanical abuse using data-driven machine learning. J. Appl. Mech. 2025, 92, 021003. [Google Scholar] [CrossRef] [Scilit]
  6. Greve, L.; Fehrenbach, C. Mechanical testing and macro-mechanical finite element simulation of the structural behaviour of cylindrical lithium-ion cells. J. Power Sources 2012, 214, 377–385. [Google Scholar] [CrossRef] [Scilit]
  7. Yu, D.; Ren, D.; Dai, K.; Zhang, H.; Zhang, J.; Yang, B.; Ma, S.; Wang, X.; You, Z. Failure mechanism and predictive model of lithium-ion batteries under extremely high transient impact. J. Energy Storage 2021, 43, 103191. [Google Scholar] [CrossRef] [Scilit]
  8. Huang, Z.X.; Zhang, X.C.; An, L.Q.; Rao, L.X.; Gu, L.R.; Li, C.Y. Dynamic response analysis of cylindrical lithium-ion battery under impact loadings: A theoretical study. Thin-Walled Struct. 2024, 205, 112385. [Google Scholar] [CrossRef] [Scilit]
  9. Qin, D.; Wang, P.; Wang, T.; Xu, H.; Chen, J. Modeling and dynamic impact analysis of prismatic lithium-ion battery. Sustainability 2023, 15, 8414. [Google Scholar] [CrossRef] [Scilit]
  10. Kociu, A.; Barbani, D.; Pugi, L.; Berzi, L.; Baldanzini, N.; Delogu, M. A finite element analysis of a lithium-ion battery cell under abuse conditions. Eng. Proc. 2025, 85, 12. [Google Scholar]
  11. Chen, X.; Yuan, Q.; Wang, T.; Ji, H.; Ji, Y.; Li, L.; Liu, Y. Experimental study on the dynamic behavior of prismatic lithium-ion battery under repeated impact. Eng. Fail. Anal. 2020, 111, 104458. [Google Scholar]
  12. Naufal, B.A.; Ubaidillah, U.; Prabowo, A.R.; Nizam, M. A review of drop test and quasi-static method test of lithium-ion battery for electric vehicle. AIP Conf. Proc. 2023, 2517, 040006. [Google Scholar]
  13. Huang, Z.X.; Zhang, X.C.; Gu, L.R.; An, L.Q.; Rao, L.X.; Liu, Y. Dynamic failure mechanisms of cylindrical lithium-ion batteries under impact loadings. Int. J. Mech. Sci. 2025, 299, 110392. [Google Scholar] [CrossRef] [Scilit]
  14. Cioni, D.; Lapostolle, L.; Costas, M.; Boles, S.; Morin, D. Influence of the state-of-charge on the mechanical behaviour of lithium-ion pouch cells under uniaxial compression. Appl. Eng. Sci. 2025, 21, 100211. [Google Scholar] [CrossRef] [Scilit]
  15. Xu, J.; Liu, B.H.; Hu, D.Y. State of charge dependent mechanical integrity behavior of 18650 lithium-ion batteries. Sci. Rep. 2016, 6, 21829. [Google Scholar] [CrossRef] [Scilit]
  16. Wang, C.; Wang, R.J.; Zhang, C.M.; Yu, Q.Q. Coupling effect of state of charge and loading rate on internal short circuit of lithium-ion batteries induced by mechanical abuse. Appl. Energy 2024, 375, 124138. [Google Scholar] [CrossRef] [Scilit]
  17. Spielbauer, M.; Soellner, J.; Berg, P.; Koch, K.; Keil, P.; Rosenmüller, C.; Bohlen, O.; Jossen, A. Experimental investigation of the impact of mechanical deformation on aging, safety and electrical behavior of 18650 lithium-ion battery cells. J. Energy Storage 2022, 55, 105564. [Google Scholar] [CrossRef] [Scilit]
  18. Sabale, S.K.; Watvisave, D.; Gaike, V.V.; Nanwatkar, R. Simulation and experimental analysis of drop and impact tests on lithium-ion battery cells to evaluate the mechanical effects on electrical parameters for enhanced battery life. SSRG Int. J. Mech. Eng. 2025, 12, 45–60. [Google Scholar]
  19. Szürke, S.K.; Szabó, M.; Szalai, S.; Fischer, S. Deformation analysis of different lithium battery designs using the DIC technique. Energies 2024, 17, 323. [Google Scholar] [CrossRef] [Scilit]
  20. Jiang, H.N.; Chen, J.; Li, X.L.; Jin, Z.Y.; Chen, T.J.; Liu, J.H.; Li, D.W. A comprehensive review of in situ measurement techniques for evaluating the electro-chemo-mechanical behaviors of battery electrodes. Molecules 2024, 29, 1873. [Google Scholar] [CrossRef] [Scilit]
  21. Sahraei, E.; Campbell, J.; Wierzbicki, T. Modeling and short circuit detection of 18650 Li-ion cells under mechanical abuse conditions. J. Power Sources 2012, 220, 360–372. [Google Scholar] [CrossRef] [Scilit]
  22. Mama, M.; Solai, E.; Capurso, T.; Danlos, A.; Khelladi, S. Comprehensive review of multi-scale lithium-ion batteries modeling: From electro-chemical dynamics up to heat transfer in battery thermal management system. Energy Convers. Manag. 2025, 325, 119223. [Google Scholar] [CrossRef] [Scilit]
  23. Wang, L.; Ling, C.; Kan, C.; Yang, C. A coupled thermal-electrical-mechanical analysis for lithium-ion battery. J. Micromech. Mol. Phys. 2022, 7, 61–70. [Google Scholar] [CrossRef] [Scilit]
  24. Ling, C.X.; Wang, L.Y.; Kan, C.D.; Yang, C. Thermal-electrical-mechanical coupled finite element models for battery electric vehicle. Machines 2024, 12, 596. [Google Scholar] [CrossRef] [Scilit]
  25. Jiang, W.; Zhou, Q.; Lu, F.; Chen, Y.; Ma, Z. A thermal-electrochemical-mechanical coupled model based on non-equilibrium thermodynamics of Li-ion batteries. J. Energy Storage 2022, 55, 105655. [Google Scholar] [CrossRef] [Scilit]
  26. Kisters, T.; Gilaki, M.; Nau, S.; Sahraei, E. Modeling of dynamic mechanical response of Li-ion cells with homogenized electrolyte-solid interactions. J. Energy Storage 2022, 49, 104069. [Google Scholar] [CrossRef] [Scilit]
  27. Jia, Y.K.; Li, J.N.; Yuan, C.H.; Gao, X.; Yao, W.R.; Lee, M.W.; Xu, J. Data-driven safety risk prediction of lithium-ion battery. Adv. Energy Mater. 2021, 11, 2003868. [Google Scholar] [CrossRef] [Scilit]
  28. Gotz, J.D.; Guerrero, G.C.; de Queiroz, J.R.H.; Viana, E.R.; Borsato, M. Diagnosing failures in lithium-ion batteries with machine learning techniques. Eng. Fail. Anal. 2023, 150, 107309. [Google Scholar] [CrossRef] [Scilit]
  29. Zhao, J.Y.; Ling, H.P.; Wang, J.B.; Burke, A.F.; Lian, Y.B. Data-driven prediction of battery failure for electric vehicles. iScience 2022, 25, 104172. [Google Scholar] [CrossRef] [Scilit]
  30. Zhang, J.Z.; Wang, Y.N.; Jiang, B.B.; He, H.W.; Huang, S.B.; Wang, C.; Zhang, Y.; Han, X.B.; Guo, D.X.; He, G.N.; et al. Realistic fault detection of Li-ion batteries via dynamical deep learning. Nat. Commun. 2023, 14, 5940. [Google Scholar] [CrossRef] [Scilit]
  31. Zhang, X.; Chen, S.; Zhu, J.; Gao, Y. A Critical Review Of Thermal Runaway Prediction And Early-Warning Methods For Lithium-Ion Batteries. Energy Mater. Adv. 2023, 4, 0008. [Google Scholar] [CrossRef] [Scilit]
  32. Hu, D.; Huang, S.; Wen, Z.; Gu, X.; Lu, J. A Review On Thermal Runaway Warning Technology For Lithium-Ion Batteries. Renew. Sustain. Energy Rev. 2024, 206, 114857. [Google Scholar] [CrossRef] [Scilit]
  33. Fathy, M.A.; Bühlmann, P. Next-Generation Potentiometric Sensors: A Review Of Flexible And Wearable Technologies. Biosensors 2025, 15, 51. [Google Scholar] [CrossRef] [Scilit]
  34. Wang, D.F.; Liang, X.; Zhang, Q.; Hao, Z.W.; Chen, S.Q.; Hu, B.B.; Xiong, K. Machine Learning-Based Early-Stage Internal Short Circuit Detection Of Lithium-Ion Batteries Using Electrochemical Impedance Spectroscopy. Electrochim. Acta 2025, 544, 147641. [Google Scholar] [CrossRef] [Scilit]
  35. Rao, L.X.; Zhou, Y.; Liu, W.J.; Han, H.L.; Qi, F.G.; Liu, H.; Wang, S.Y.; Zhao, J.H.; Zhang, Y.J.; Zhang, X.C. Machine-learning-assisted design of re-entrant honeycomb metamaterials with tunable mechanical properties. Int. J. Mech. Sci. 2025, 305, 110778. [Google Scholar] [CrossRef] [Scilit]
  36. Zhang, X.C.; Song, Z.Y.; Li, Y.N.; Xiao, L.J.; Xu, Z.; Rao, L.X.; Ci, T.J.; Hui, X.L. Generative inverse design of metamaterials with customized stress-strain response. Int. J. Mech. Sci. 2025, 306, 110875. [Google Scholar] [CrossRef] [Scilit]
  37. Zhang, C.; Zhu, Y.; Dong, G.; Wei, J. Data-driven lithium-ion battery states estimation using neural networks and particle filtering. Int. J. Energy Res. 2019, 43, 8230–8241. [Google Scholar] [CrossRef] [Scilit]
Figure 1. Drop-weight impact test system: (a) Drop-weight impact machine. (b) Battery specimen. (c) Charge–discharge profile of the LIB. (d) Loading conditions and different indenter geometries. (e) Dynamic signal testing and analysis system.
Energies 19 01435 g001
Figure 2. Schematic diagram of the ML models: (a) TCN. (b) LSTM. (c) ANN. (d) SVR. (e) XGBoost. (f) RF.
Energies 19 01435 g002
Figure 3. Data characteristics of the dynamic mechanical failure dataset for cylindrical LIBs: (a) different indenters; (b) repeated impacts; (c) different SOC.
Energies 19 01435 g003
Figure 4. Force prediction of LIBs with different indenter conditions using various ML models: (a) TCN. (b) LSTM. (c) ANN. (d) SVR. (e) XGBoost. (f) Random Forest.
Energies 19 01435 g004
Figure 5. Comparison of evaluation metrics for six ML models under different indenter conditions: (a) Hemispherical indenter. (b) Cylindrical flat indenter.
Energies 19 01435 g005
Figure 6. Force prediction of LIBs under repeated impacts using different ML models: (a) TCN. (b) LSTM. (c) ANN. (d) SVR. (e) XGBoost. (f) Random Forest.
Energies 19 01435 g006
Figure 7. Comparison of evaluation metrics for six ML models under repeated loading conditions: (a) First impact. (b) Second impact.
Energies 19 01435 g007
Figure 8. Force prediction of LIBs under different SOC using various ML models: (a) TCN. (b) LSTM. (c) ANN. (d) SVR. (e) XGBoost. (f) Random Forest.
Energies 19 01435 g008
Figure 9. Comparison of evaluation metrics for six ML models under different SOC levels: (a) SOC = 0. (b) SOC = 0.3. (c) SOC = 0.6.
Energies 19 01435 g009
Table 1. Main specifications of the NCR18650B LIB.
ParameterValue
Dimension (mm)65 × 18
Rated capacity (mAh)3.4
Charge cutoff voltage (V)4.2 ± 0.03
Nominal voltage (V)3.6
Discharge cutoff voltage (V)2.5
Internal resistance (mΩ)<100 mΩ
Mass (g)<50
Table 2. Dynamic loading conditions and sample size for cylindrical LIBs.
DatasetImpact Velocity (m/s)Impact RepetitionsSOCLoading ConditionNumber of Samples (Time Points)
Dataset 1210% SOCCylindrical flat indenter6024
210% SOCHemispherical indenter7679
Dataset 21.710% SOCCylindrical flat indenter4073
1.720% SOCCylindrical flat indenter2779
Dataset 31.710% SOCCylindrical flat indenter2910
1.7130% SOCCylindrical flat indenter2779
1.7160% SOCCylindrical flat indenter2902
Table 3. Hyperparameter settings and training configuration for six ML models.
ModelCore HyperparametersTraining SettingsRandom Seed
ANNHidden layers 3;
hidden units 128, 128, 64;
activation ReLU; output dim 1
Optimizer Adam; lr 1 × 10⁻³; batch size 256; epochs 300; loss MSE42
LSTMHidden size 64;
layers 2;
output dim 1
Optimizer Adam; lr 1 × 10⁻³; batch size 128; epochs 200; loss MSE42
TCNChannels 64, 64, 64;
kernel size 3;
dilations 1, 2, 4;
output dim 1
Optimizer Adam; lr 1 × 10⁻³; batch size 128; epochs 200; loss MSE42
SVRKernel rbf; C 100; epsilon 0.01; gamma scale; tol 1 × 10⁻³; max_iter 100,000 42
RFn_estimators 500;
max_depth 20;
max_features sqrt;
min_samples_split 2;
min_samples_leaf 1;
bootstrap True
42
XGBoostobjective reg:squarederror; n_estimators 1000;
max_depth 6;
learning_rate 0.05;
subsample 0.8;
colsample_bytree 0.8;
min_child_weight 1;
gamma 0;
reg_lambda 1.0;
reg_alpha 0.0
42
Disclaimer/Publisher’s Note: The statements, opinions and data contained in all publications are solely those of the individual author(s) and contributor(s) and not of MDPI and/or the editor(s). MDPI and/or the editor(s) disclaim responsibility for any injury to people or property resulting from any ideas, methods, instructions or products referred to in the content.