Communication

Finite-Time Dynamic Tracking Control of Parallel Robots with Uncertainties and Input Saturation
School of Electrical and Information Engineering, Jiangsu University, Zhenjiang 212013, China
*
Author to whom correspondence should be addressed.
Sensors 2021, 21(9), 2996; https://doi.org/10.3390/s21092996
Submission received: 15 March 2021 / Revised: 16 April 2021 / Accepted: 22 April 2021 / Published: 24 April 2021
(This article belongs to the Section Sensors and Robotics)

Abstract

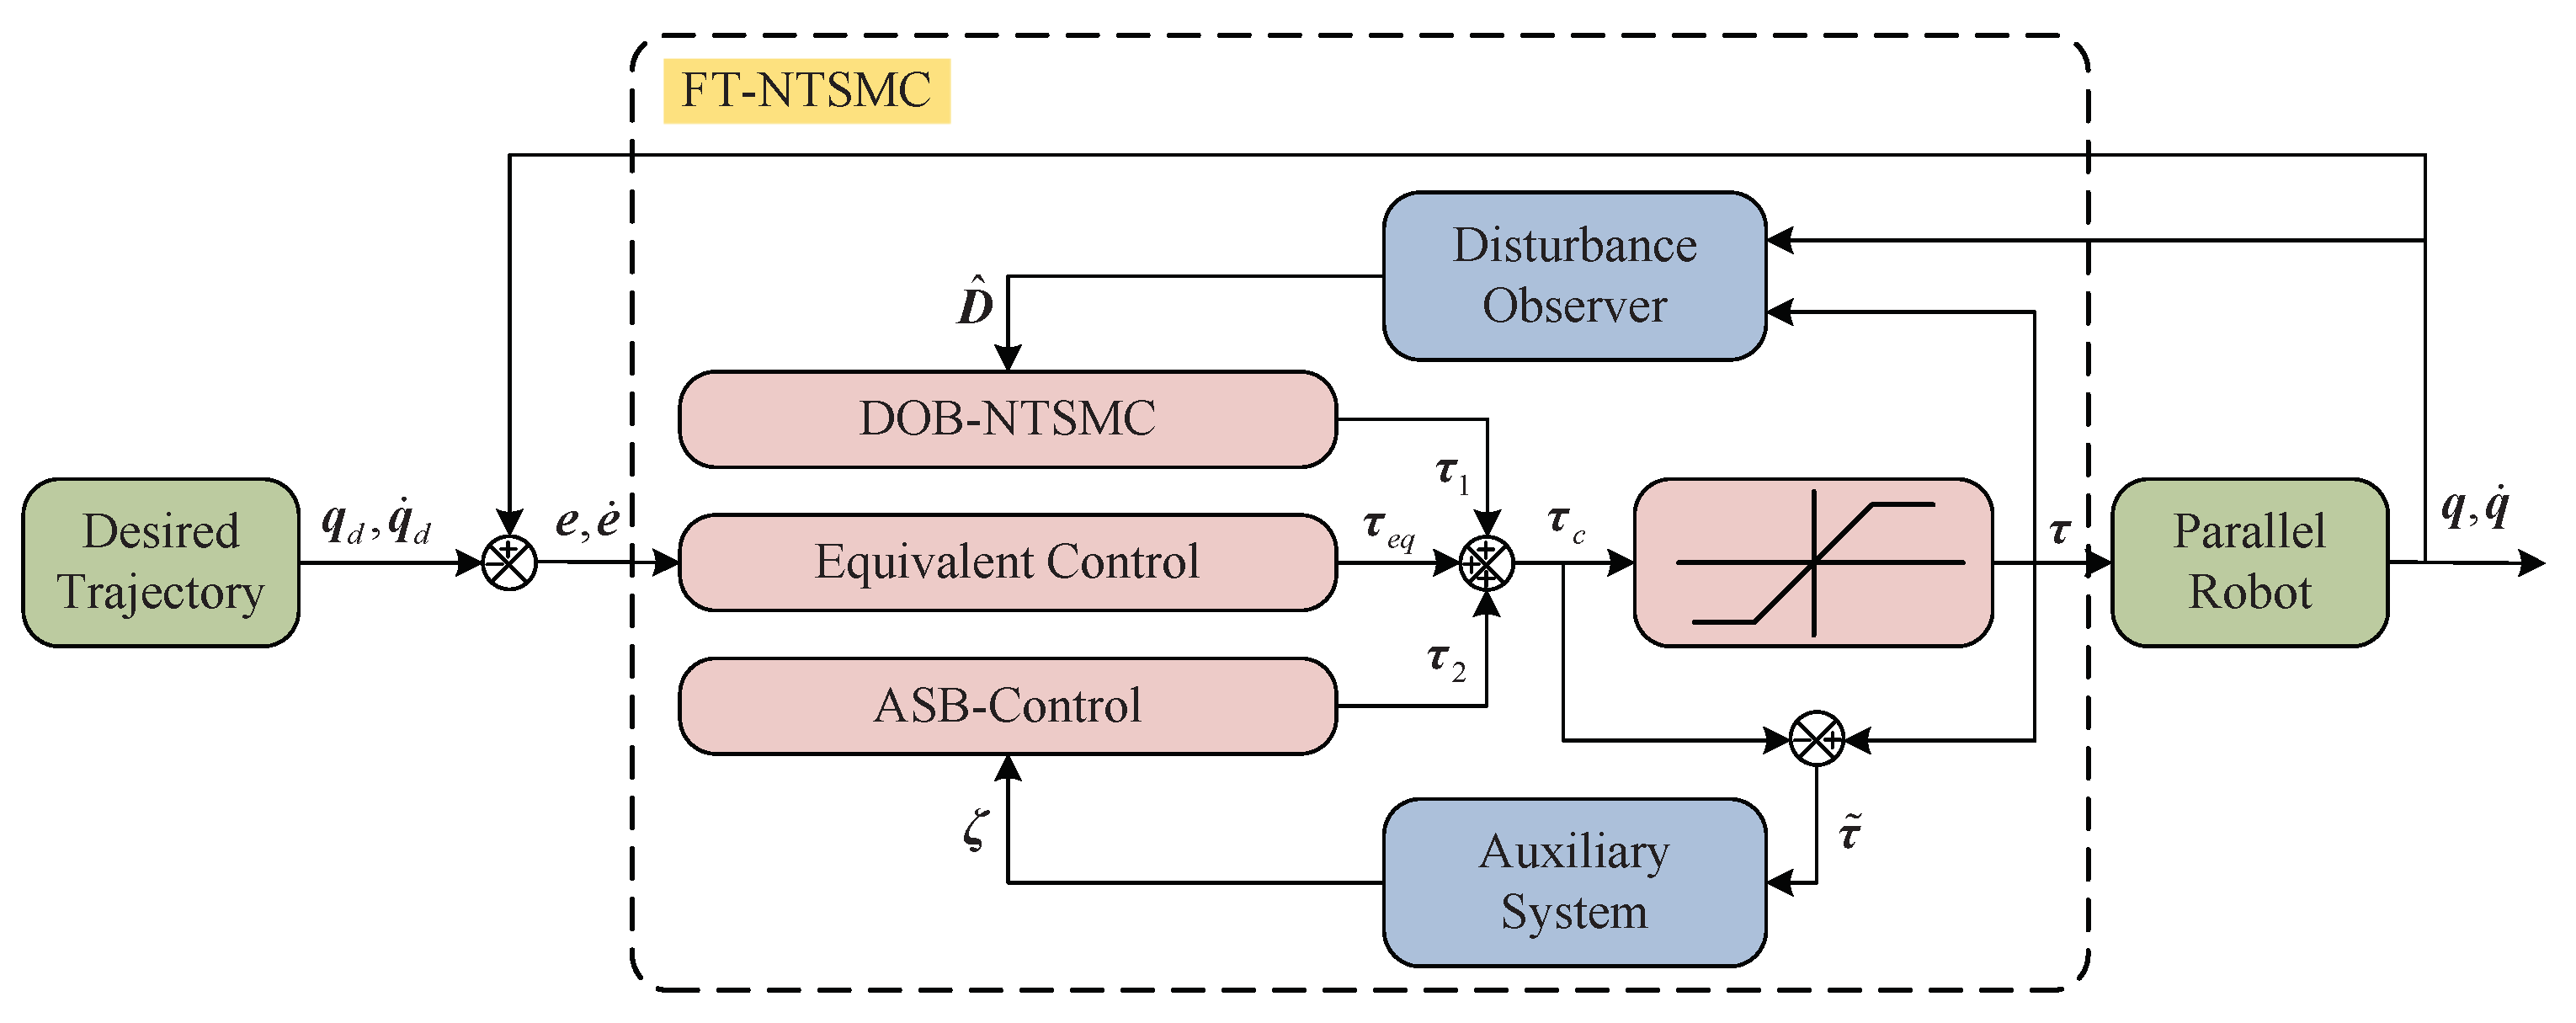
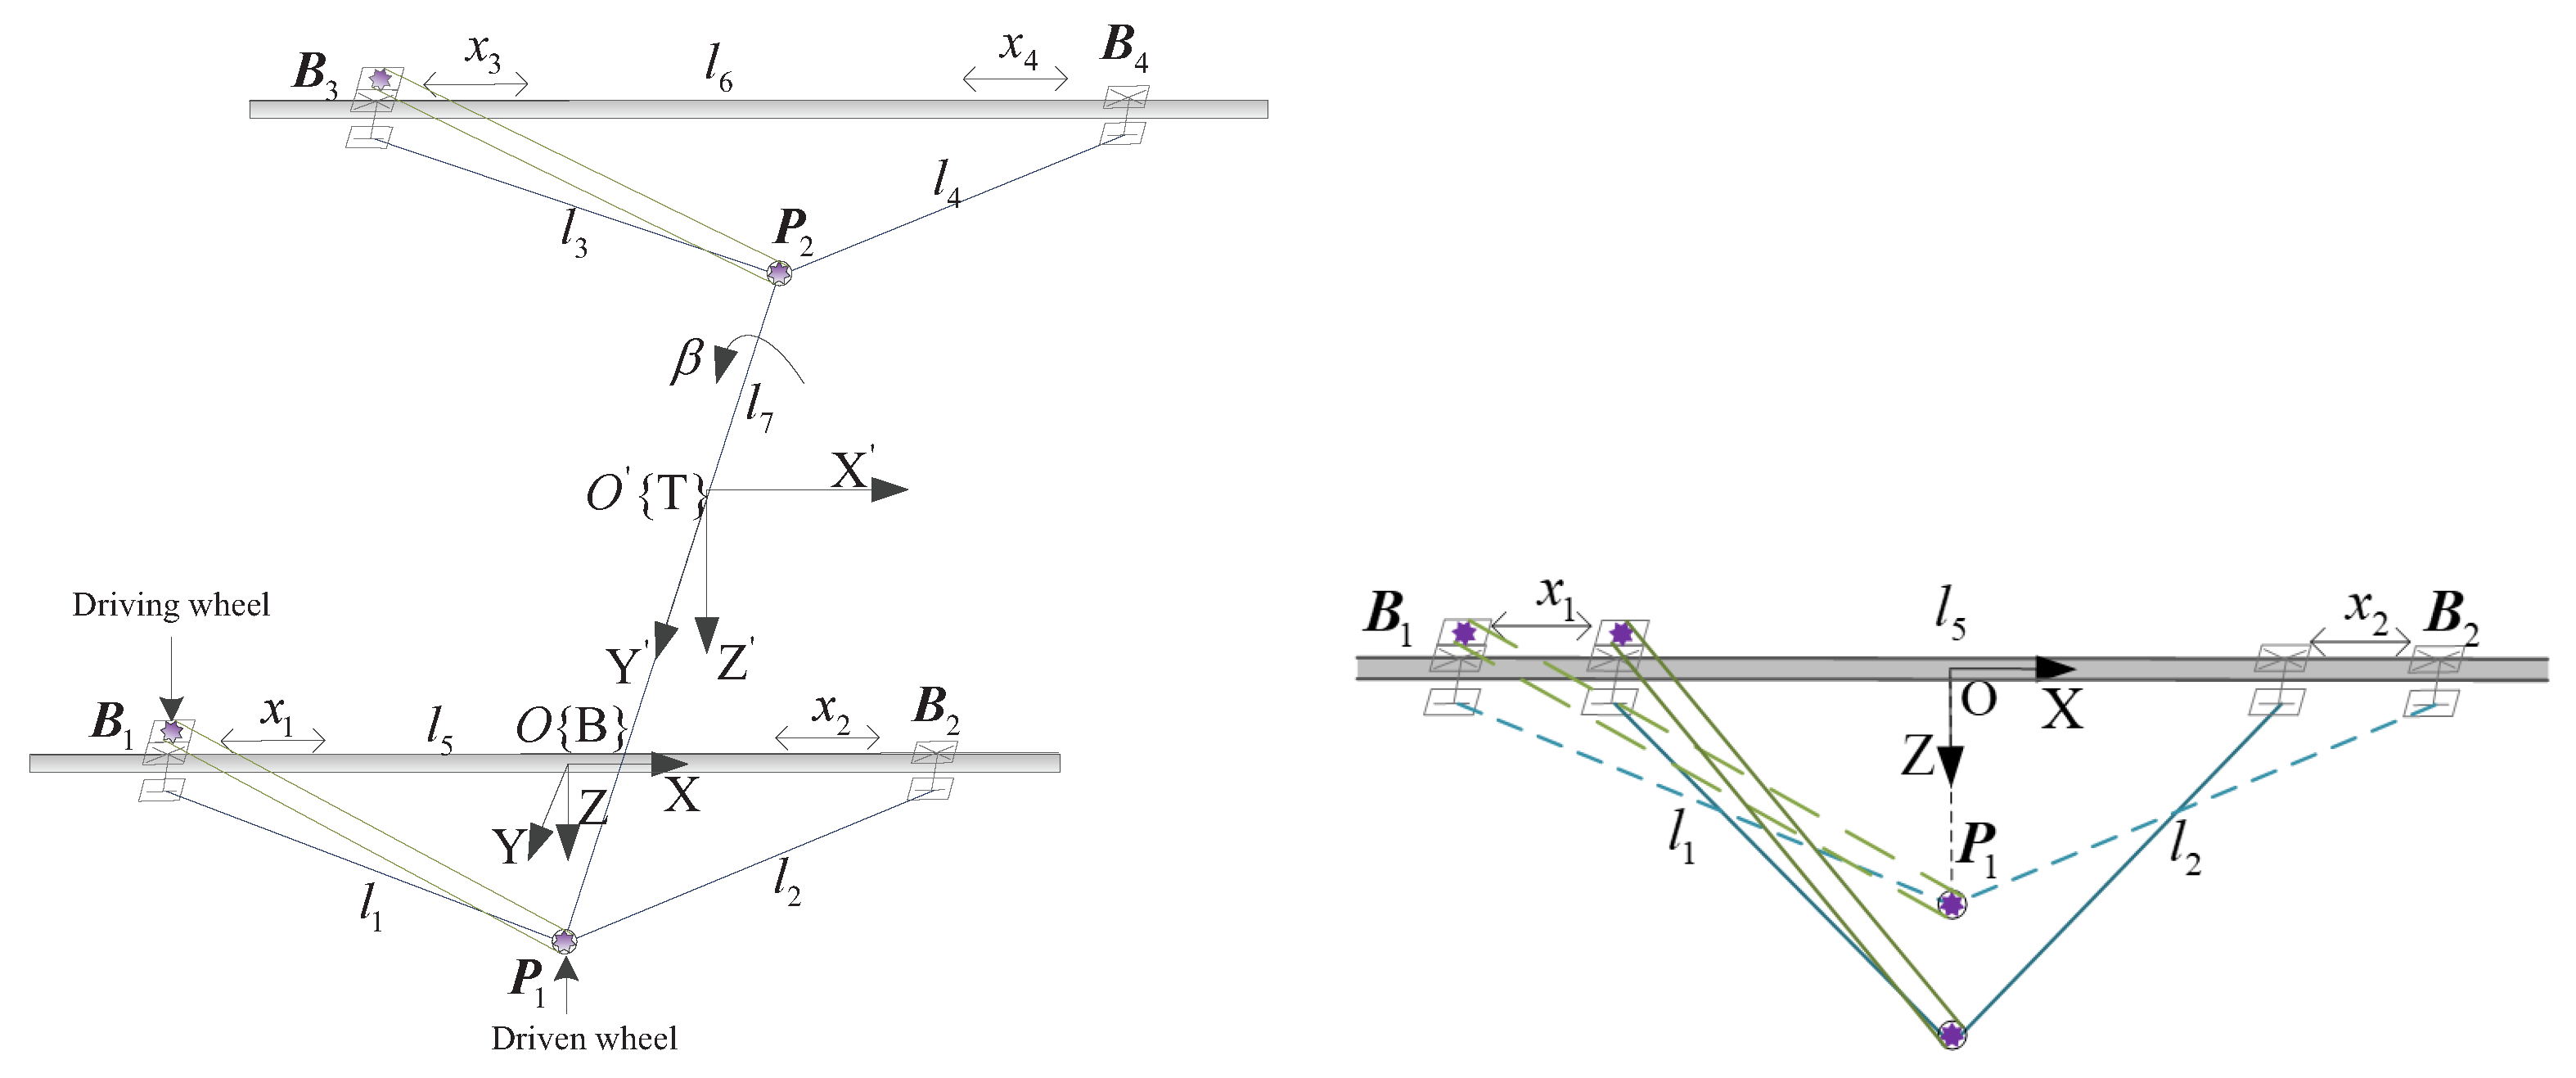
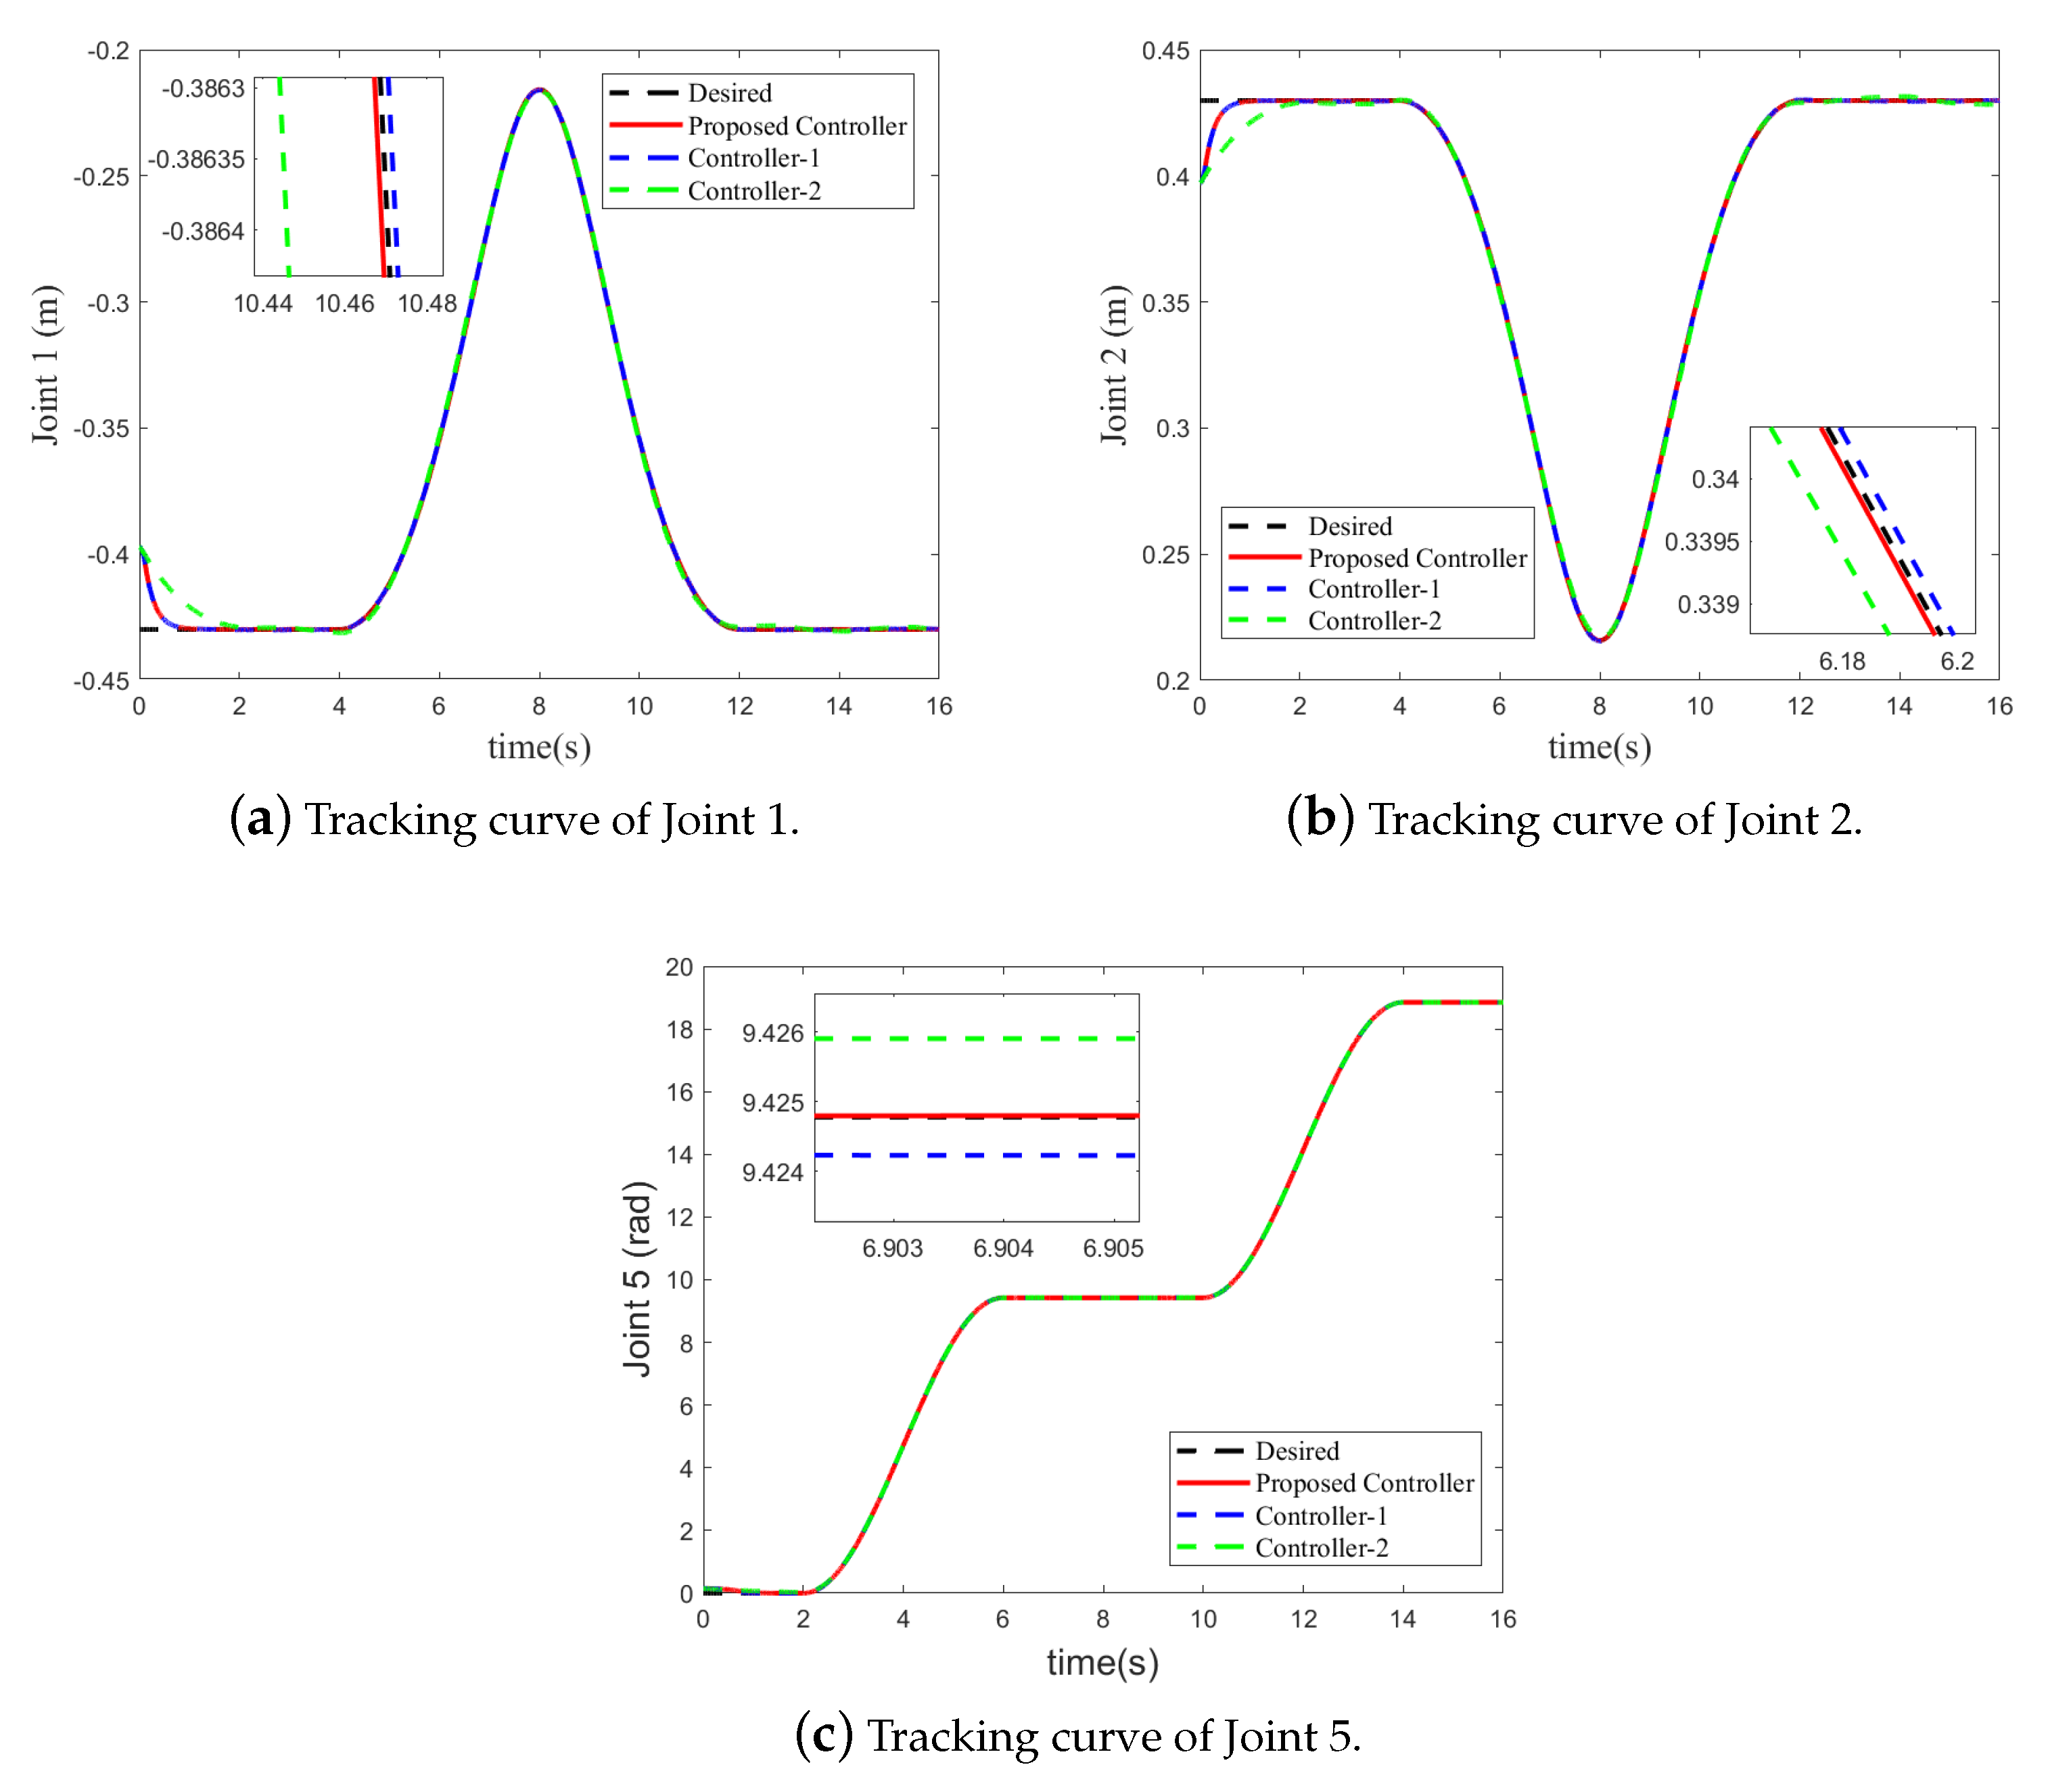
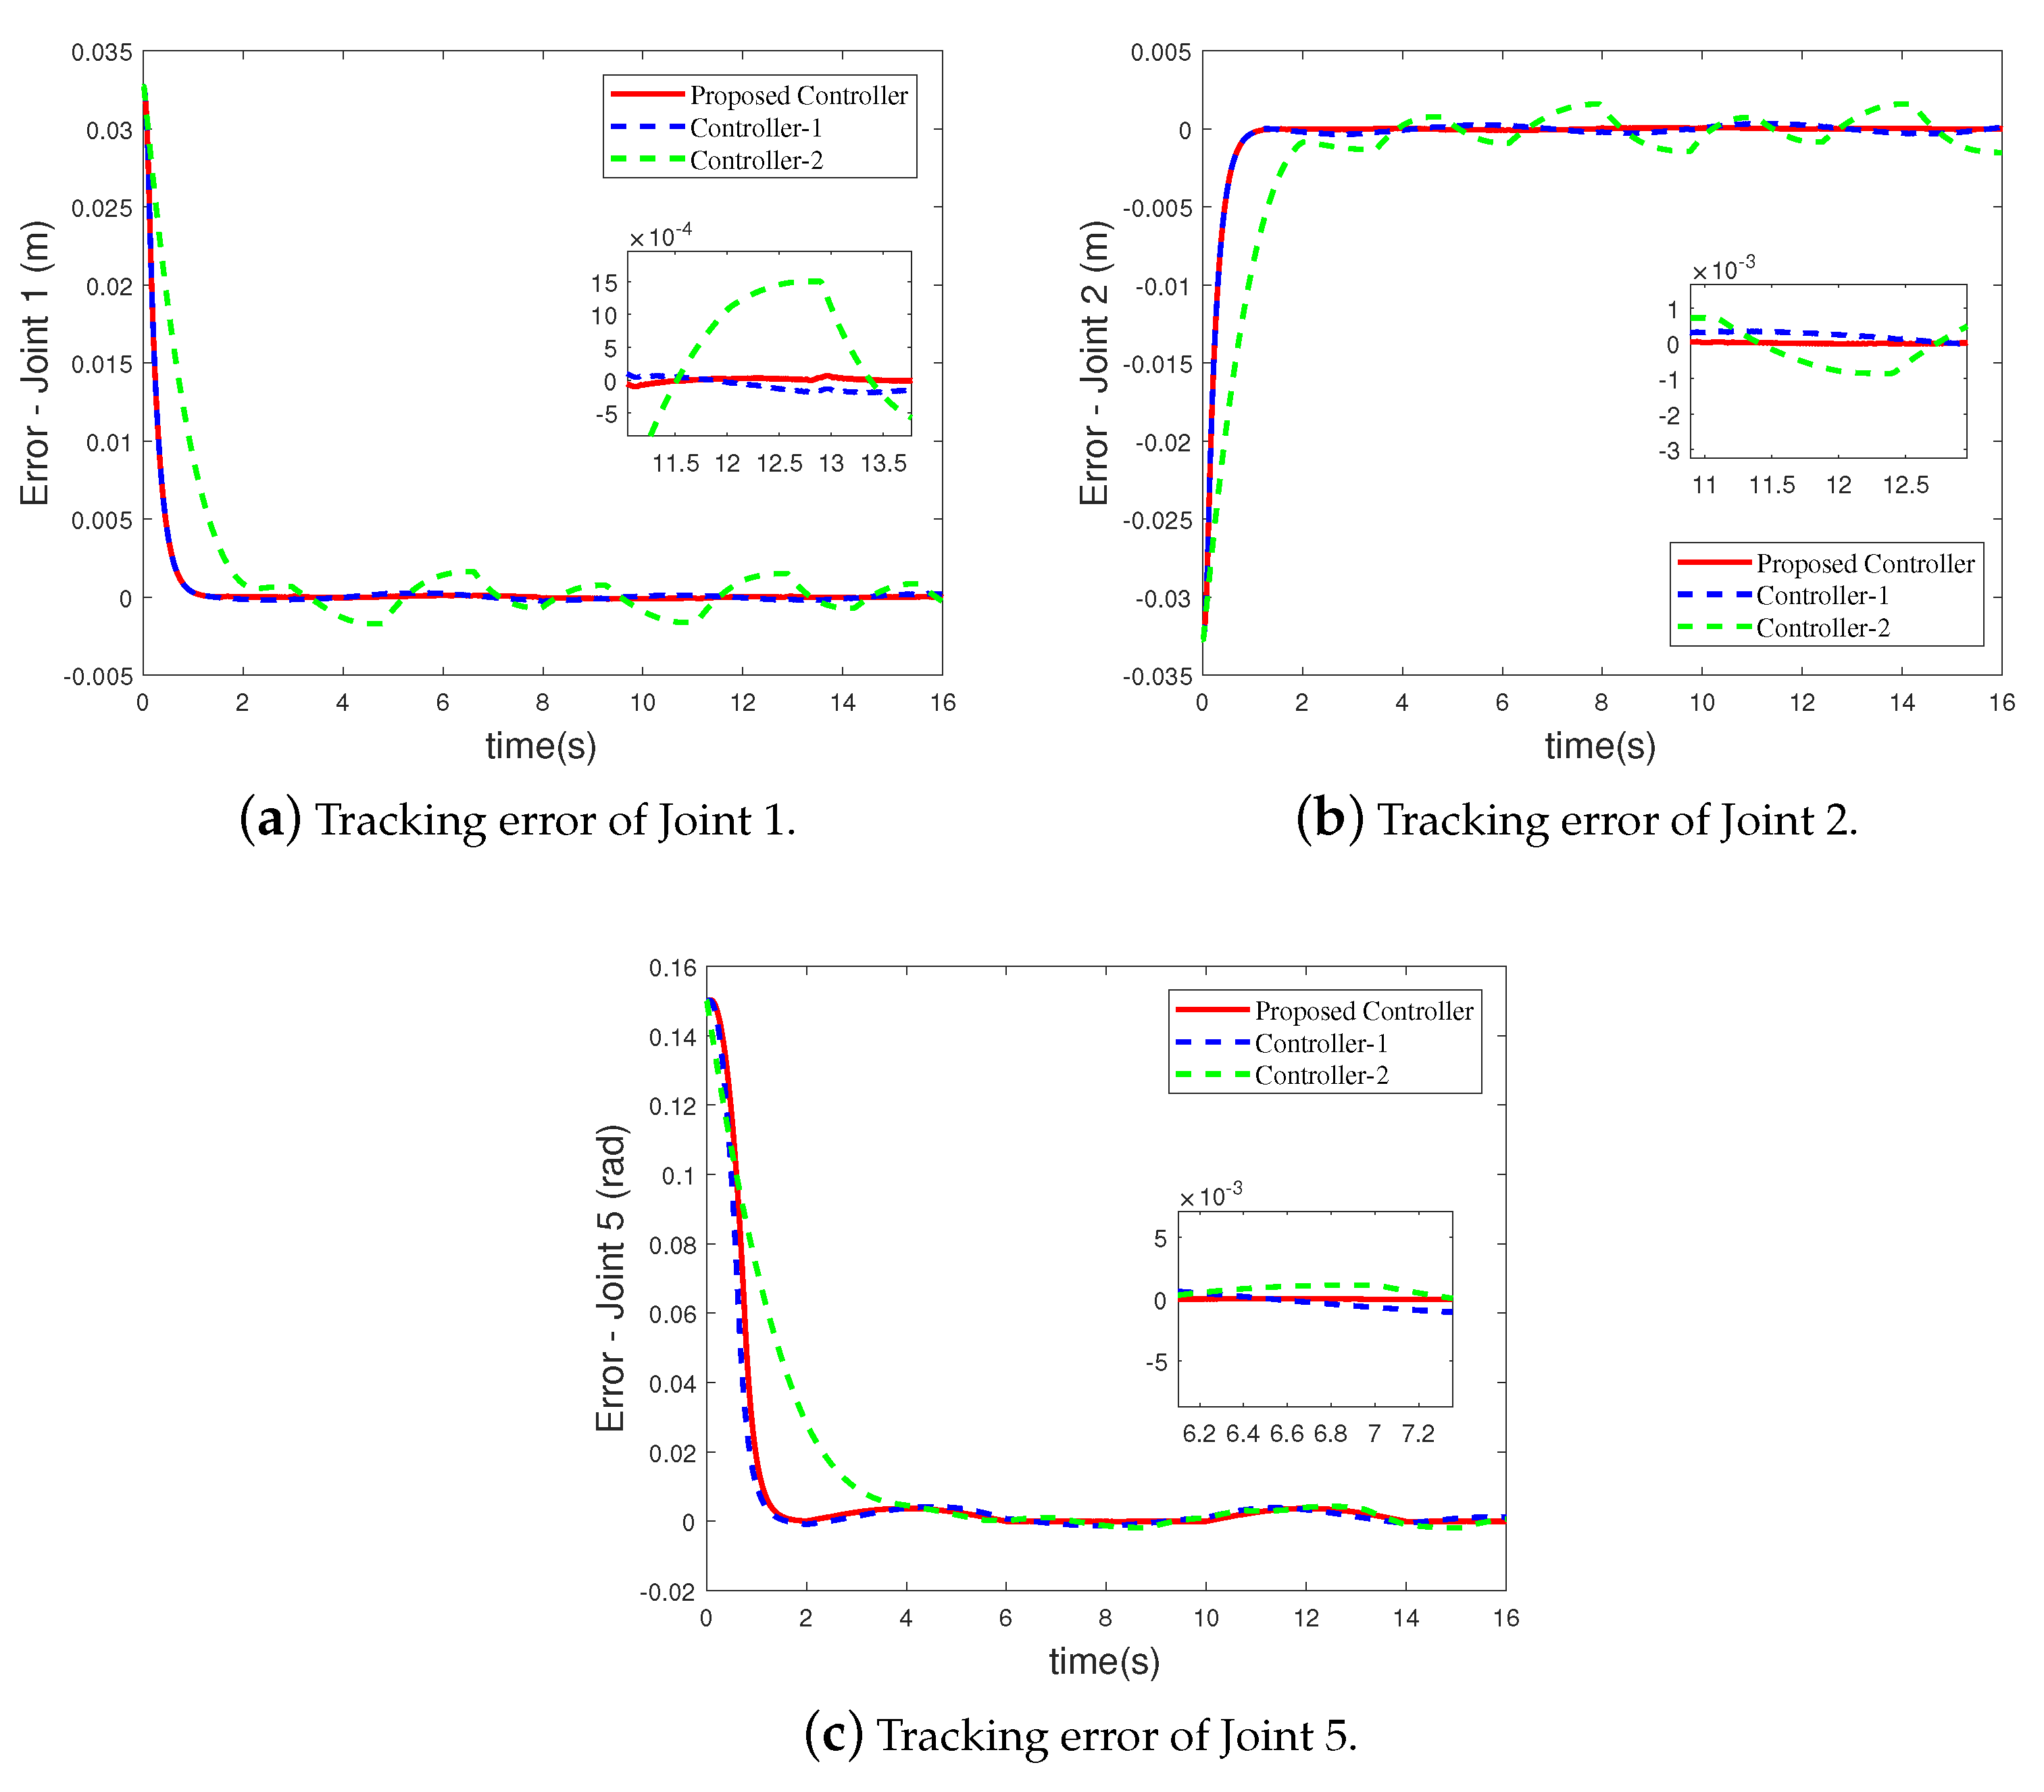
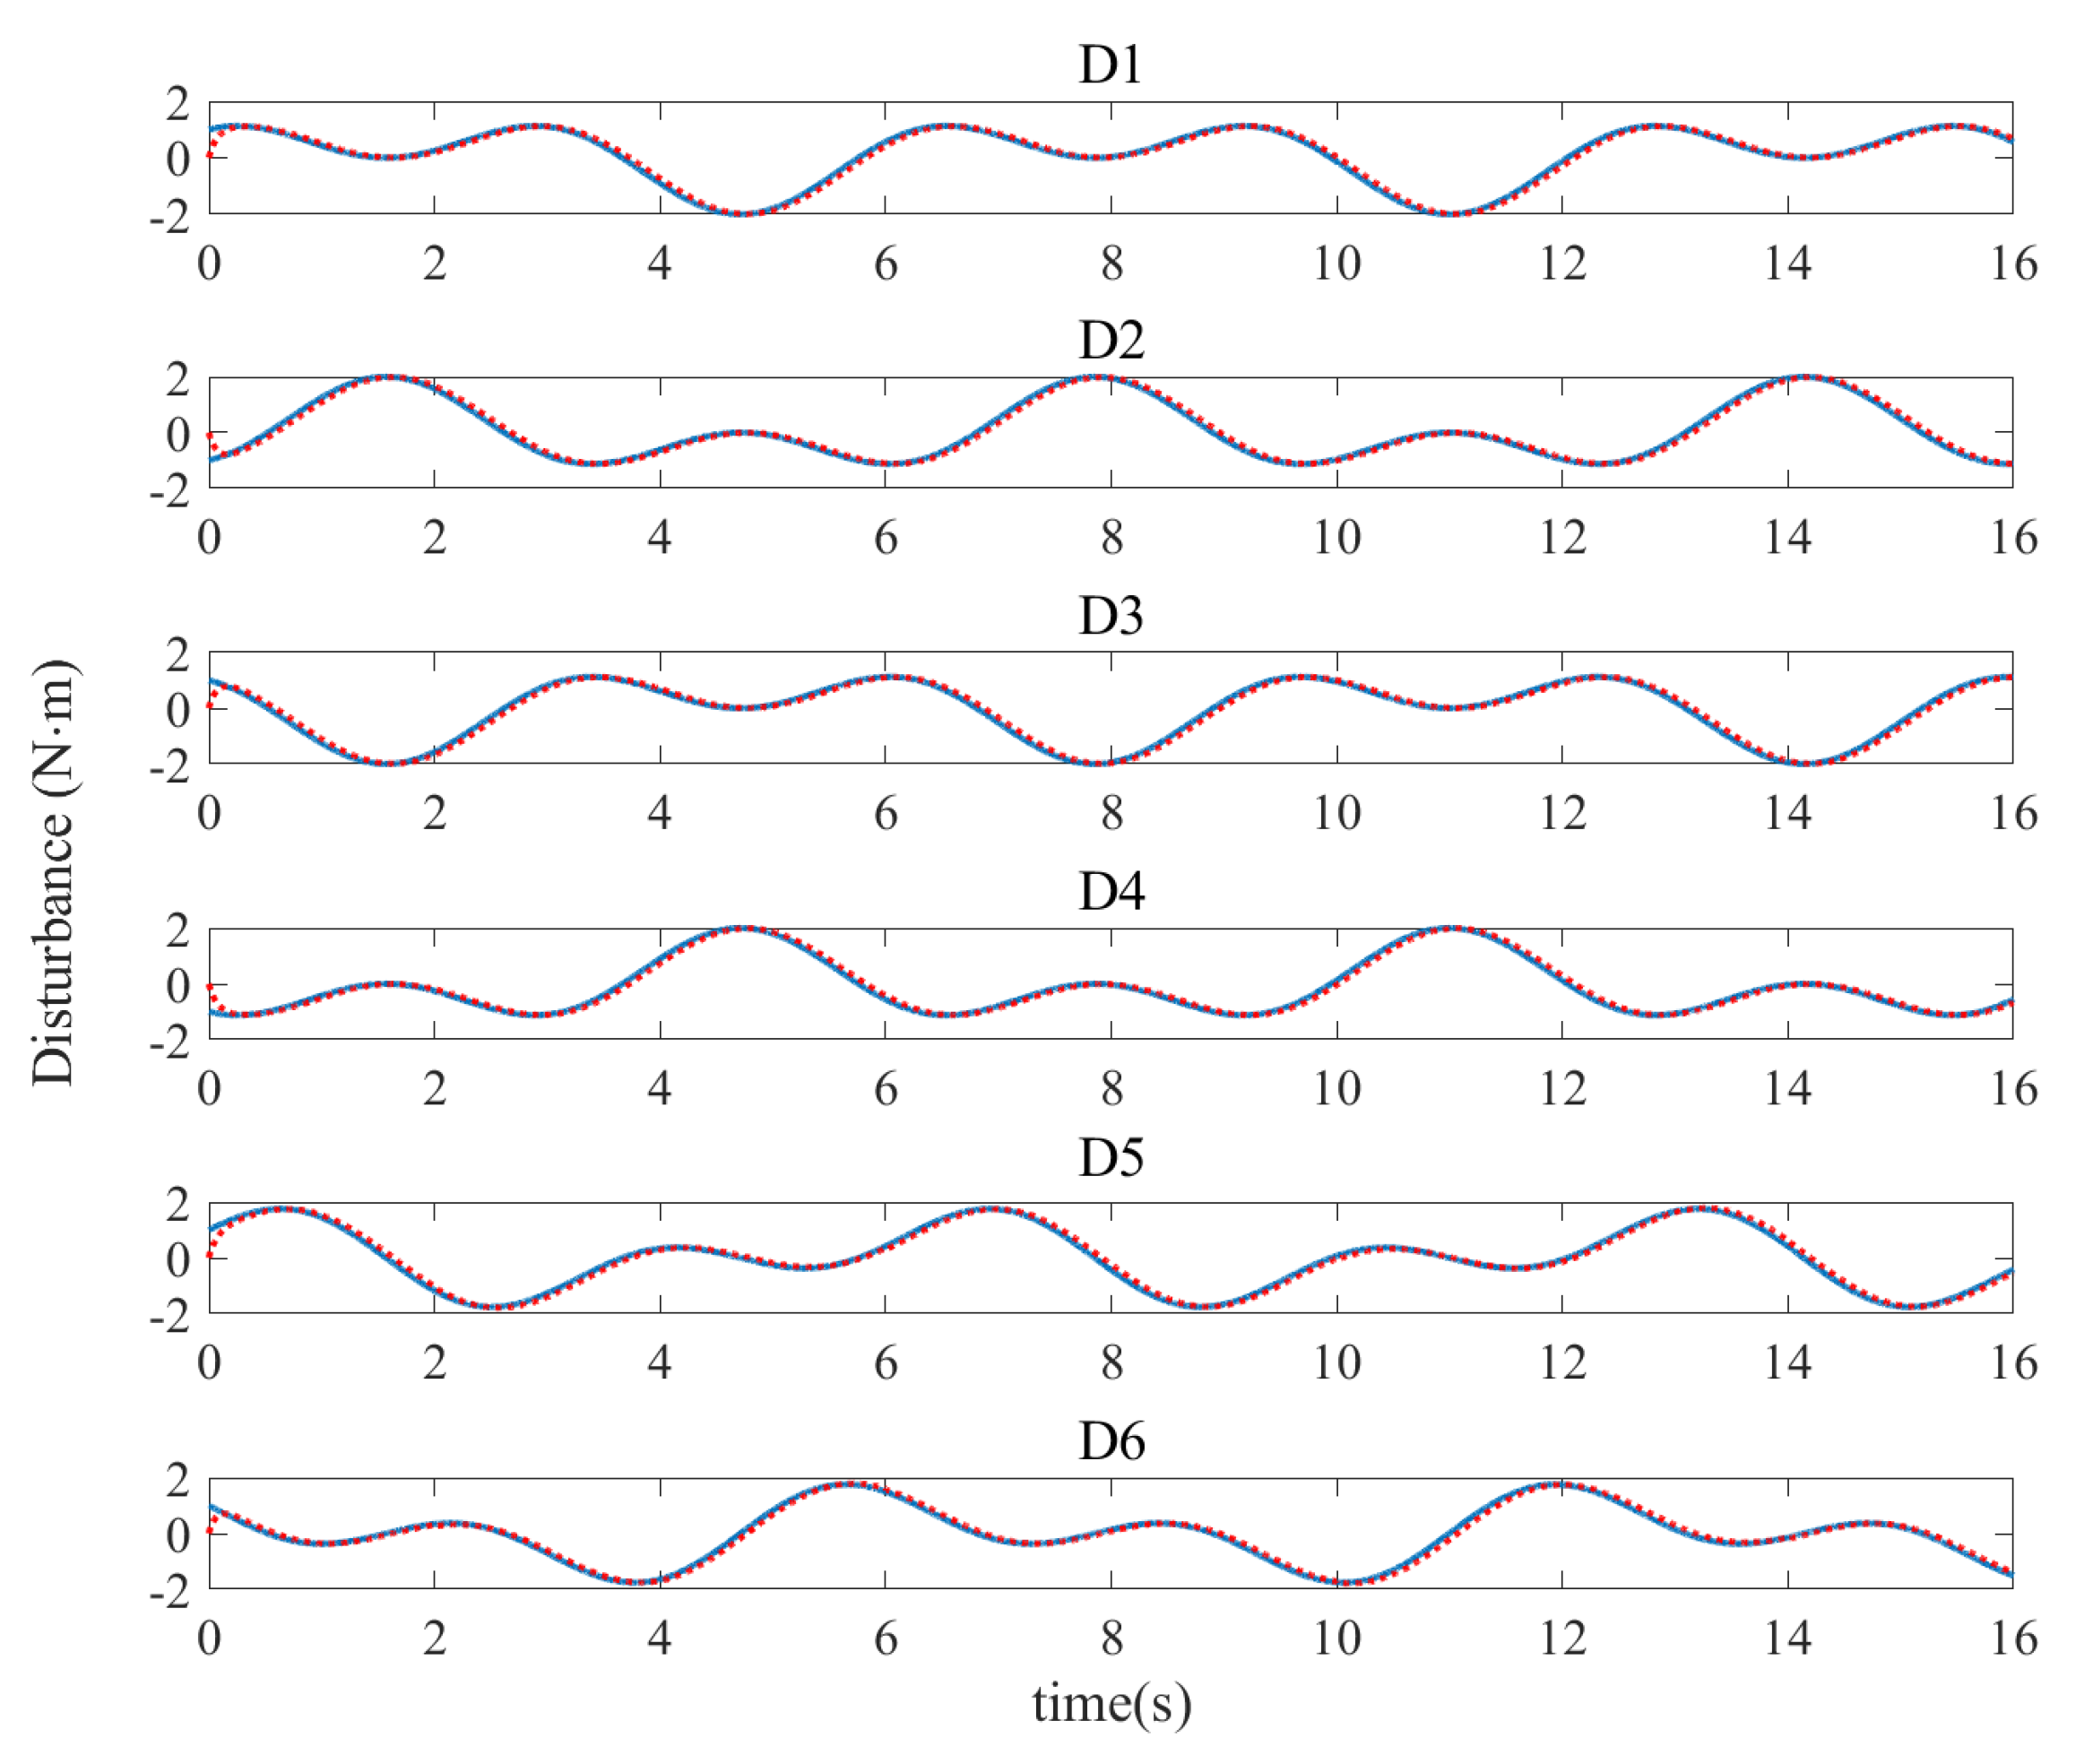
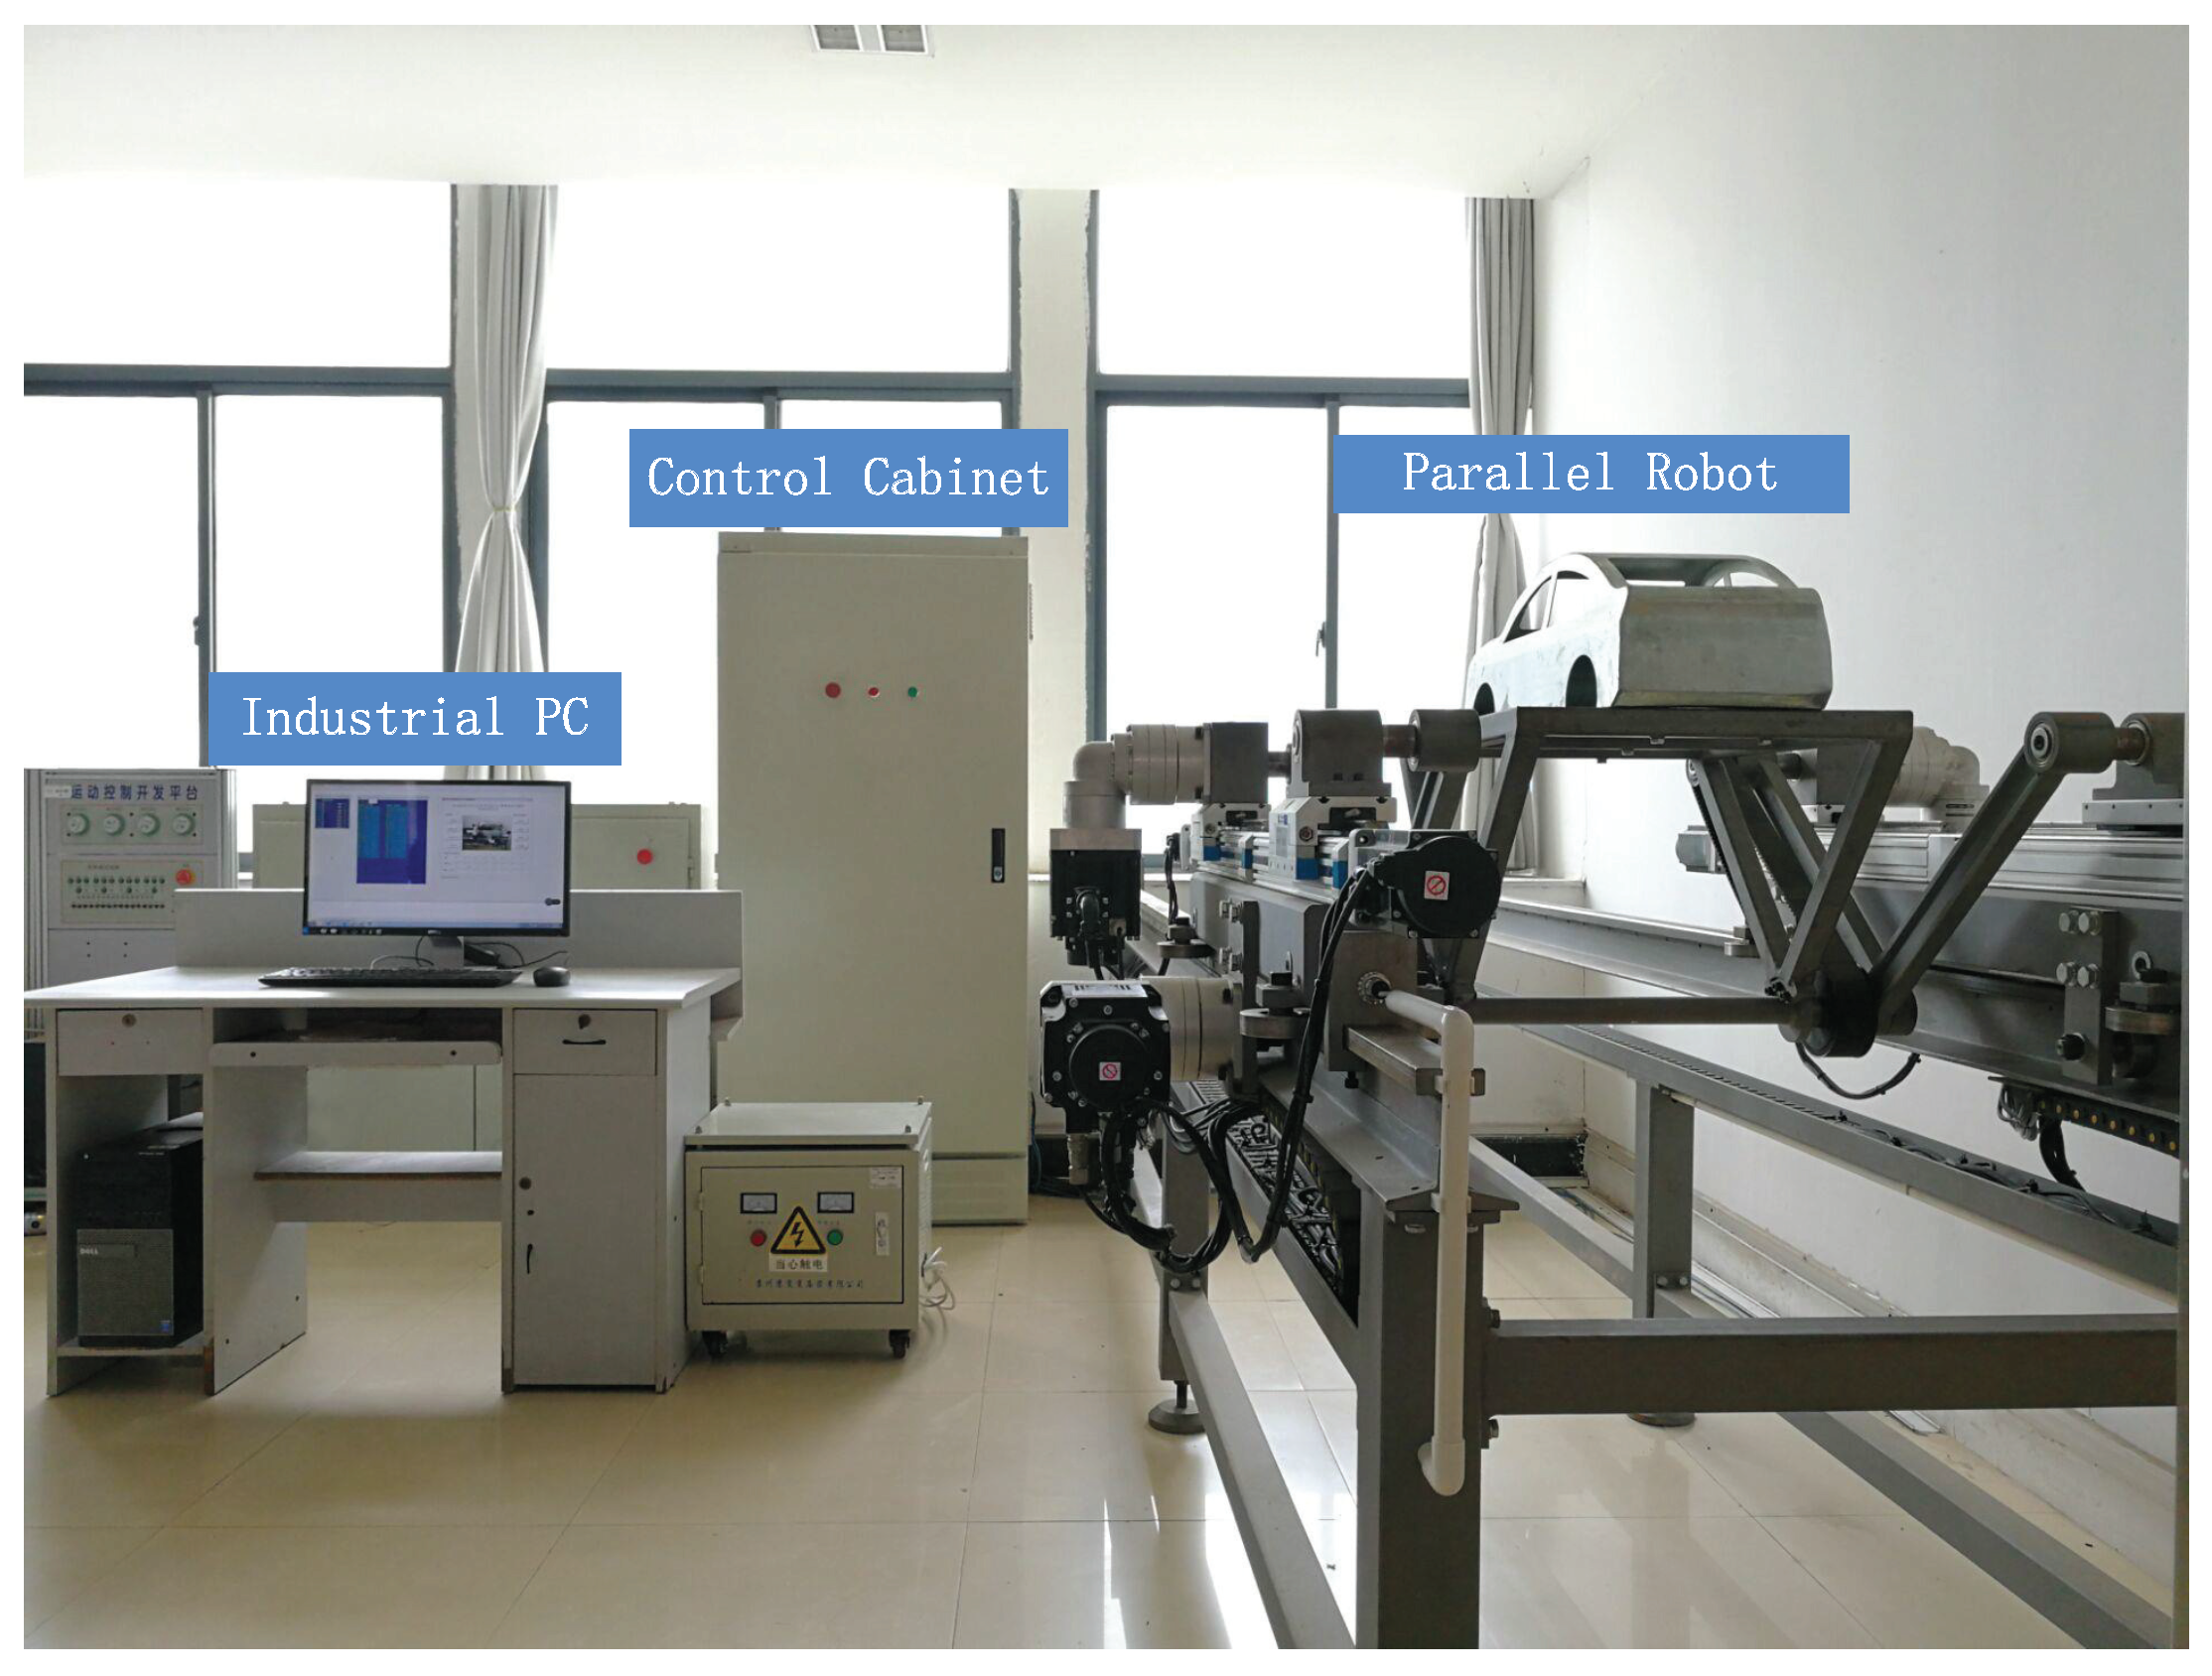
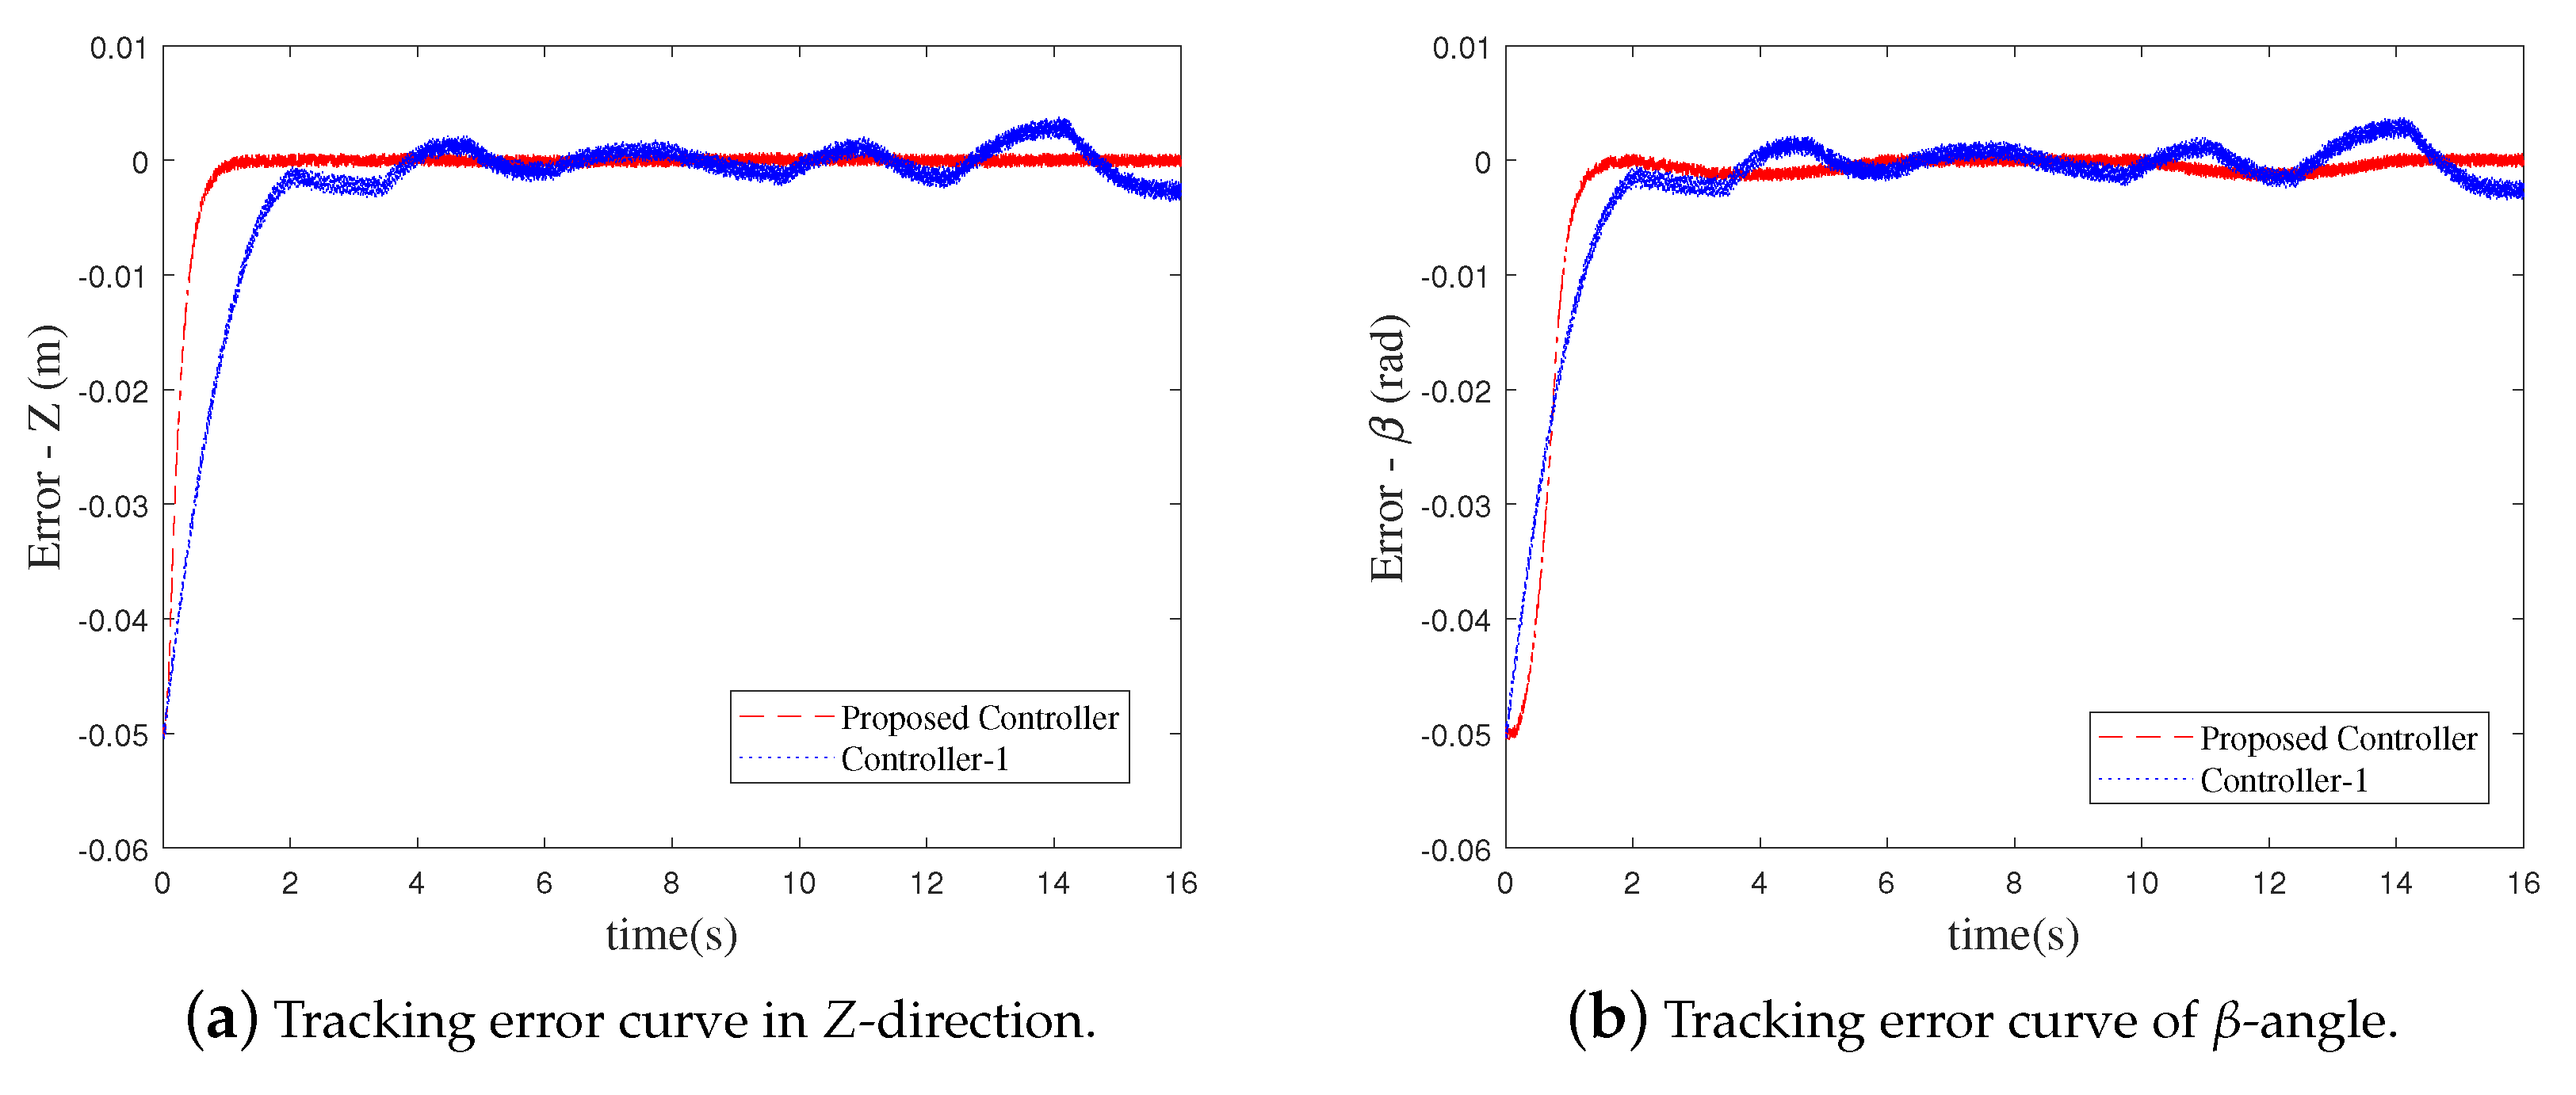
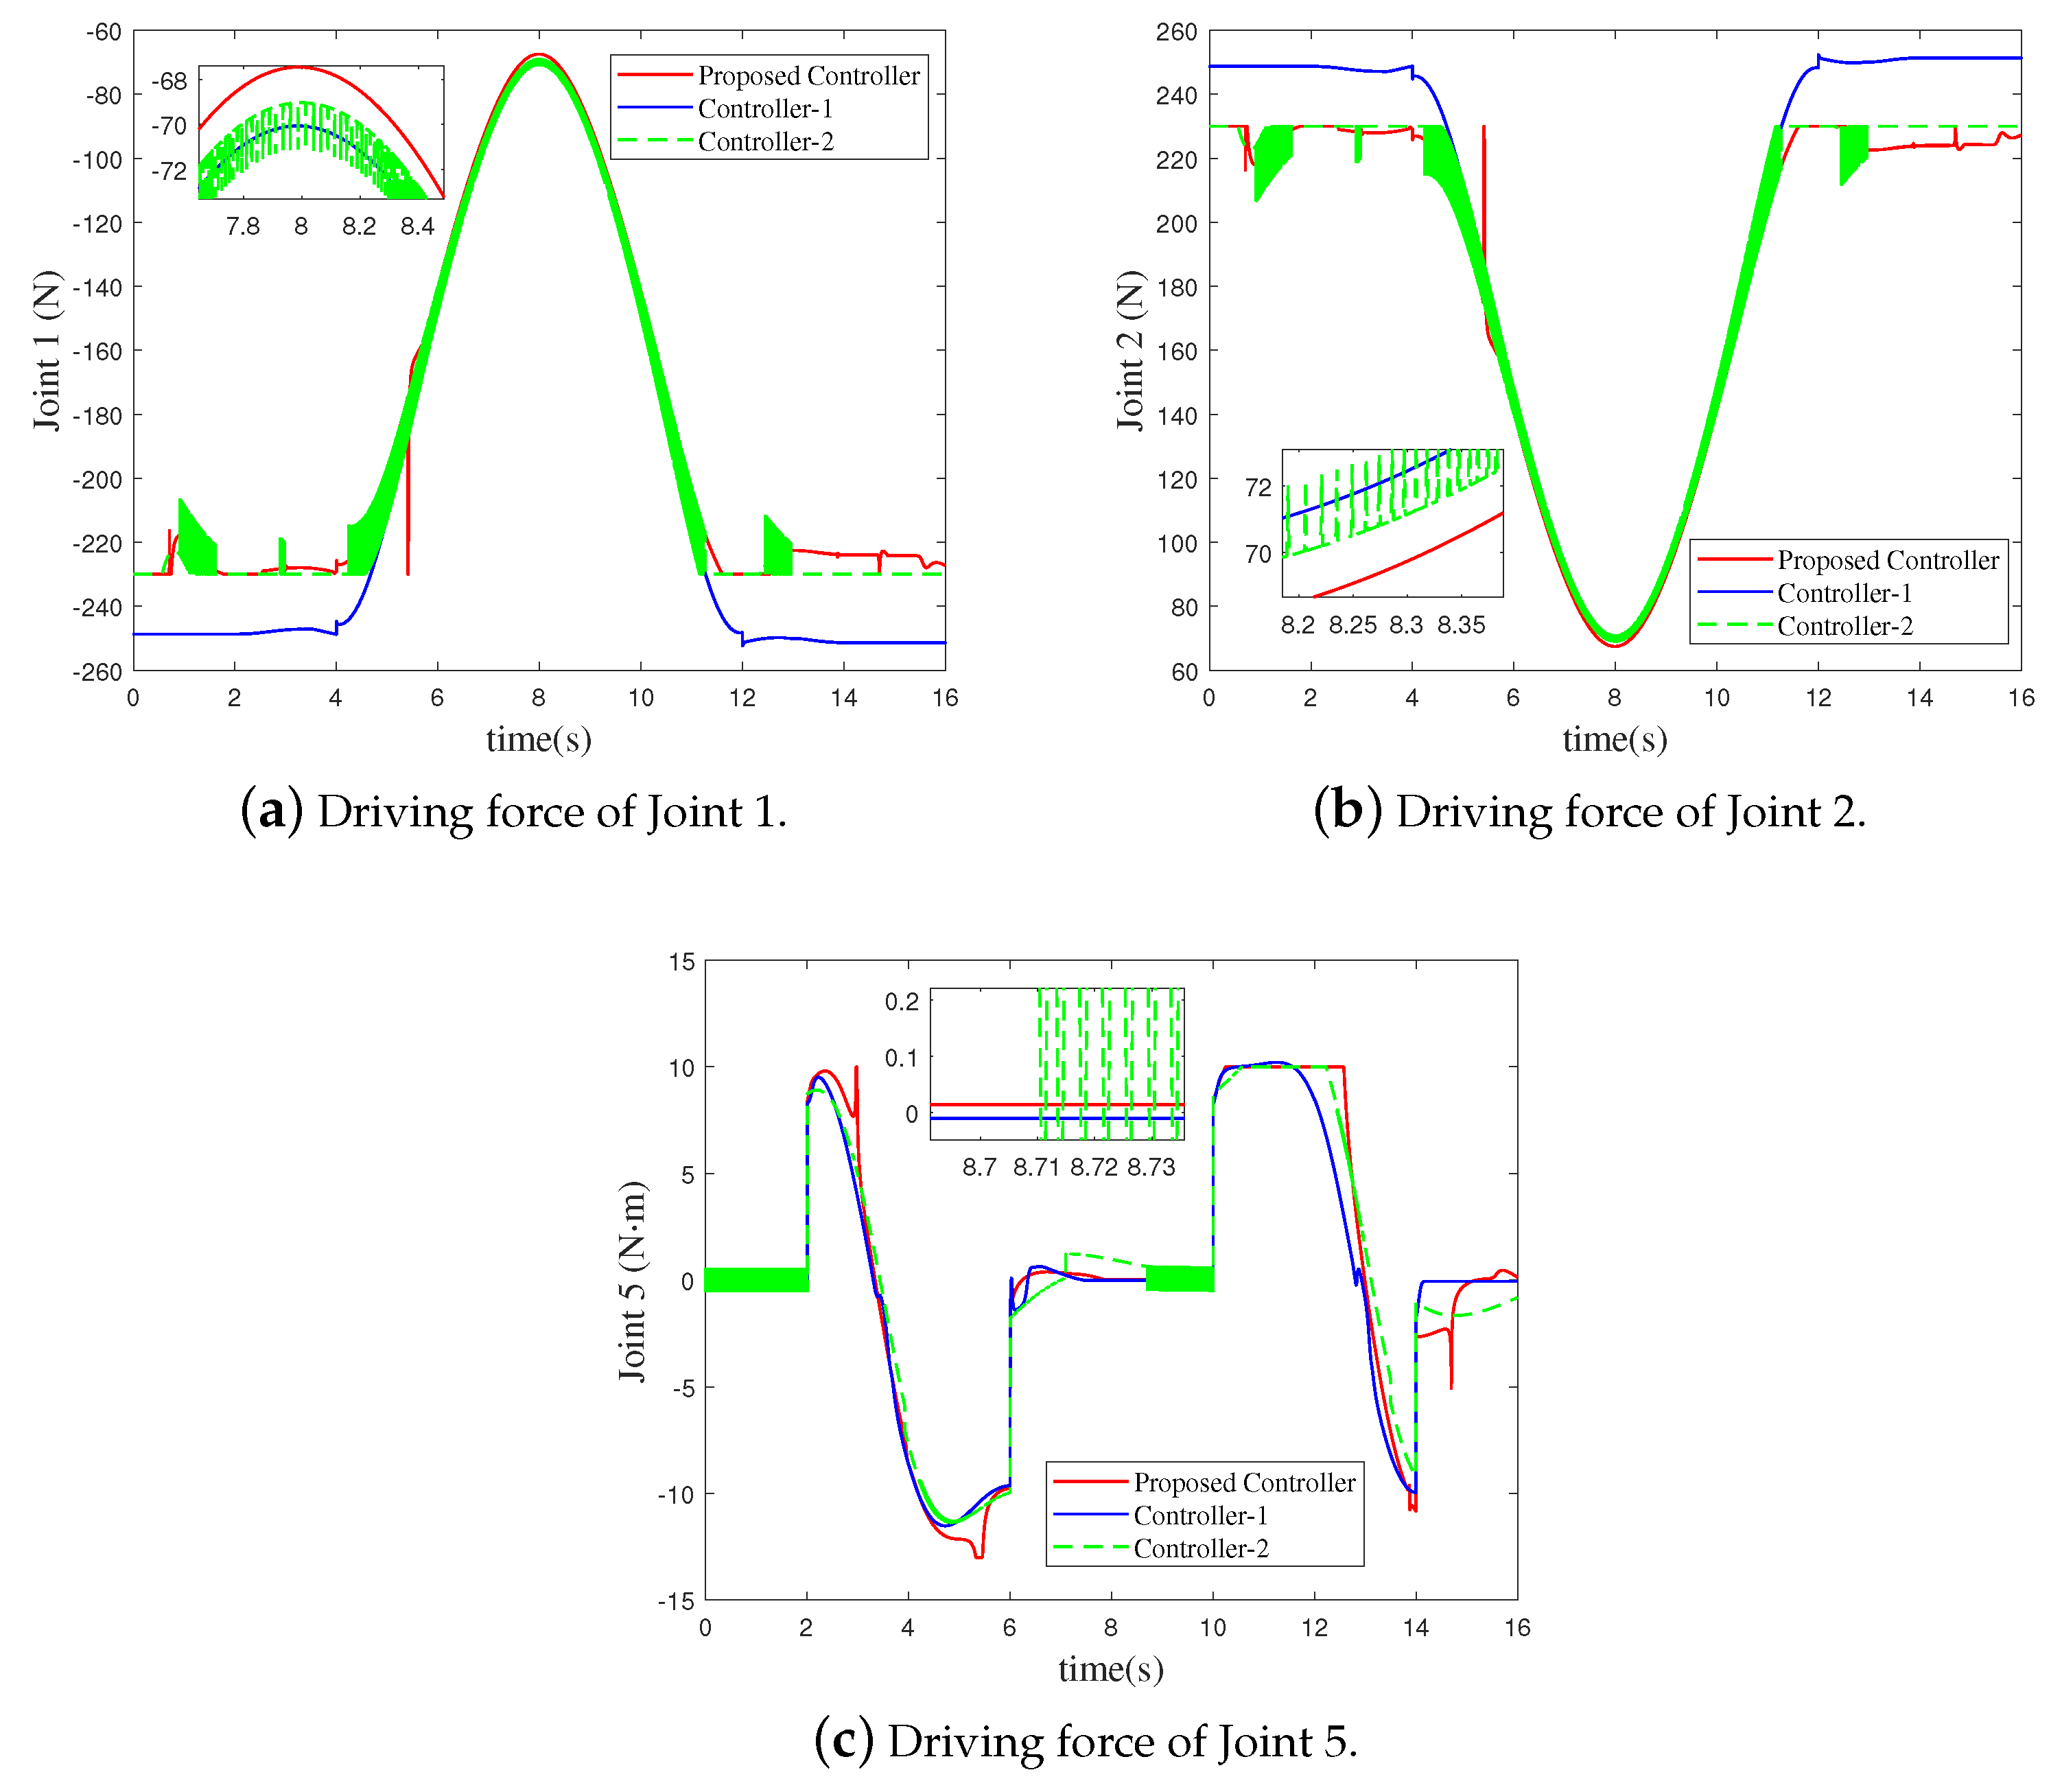
This paper considers the finite-time dynamic tracking control for parallel robots with uncertainties and input saturation via a finite-time nonsingular terminal sliding mode control scheme. A disturbance observer is designed to estimate the lumped disturbance in the dynamic model of the parallel robot, including modeling errors, friction and external disturbance. By introducing the fractional exponential powers into the existing asymptotic convergent auxiliary system, a novel finite-time convergent auxiliary system is constructed to compensate for input saturation. The finite-time nonsingular terminal sliding mode control is proposed based on the disturbance estimation and the state of the novel auxiliary system, so that the convergence performance, control accuracy and robustness are improved. Due to the estimation and compensation for the lumped disturbance, the inherent chattering characteristic of sliding mode control can be alleviated by reducing the control gain. The finite-time stability of the closed-loop system is proved with Lyapunov theory. Finally, simulation and experimental research on the dynamic control of a conveying parallel robot are carried out to verify the effectiveness of the proposed method.
Keywords: parallel robot; finite-time control; input saturation; auxiliary system; nonsingular terminal sliding mode; disturbance observer parallel robot; finite-time control; input saturation; auxiliary system; nonsingular terminal sliding mode; disturbance observer