


Abstract
Enhancing quadrotor control to improve both precision and responsiveness is essential for expanding their deployment in complex and dynamic environments. These aerial vehicles are widely used in applications, such as aerial mapping, delivery, disaster response, and defense, where maintaining stability and accuracy is critical, especially under external disturbances like wind. This paper makes three key contributions. First, it develops a nonlinear mathematical model of a quadrotor and designs a backstepping controller for trajectory tracking. Second, the controller’s parameters are optimized using three nature-inspired algorithms: Gray Wolf Optimization (GWO), Particle Swarm Optimization (PSO), and the Flower Pollination Algorithm (FPA), enabling performance comparisons in terms of their tracking precision and control effort. Third, the robustness of the best-performing optimized controller is evaluated by applying wind disturbances at the simulation level, modeled as external forces acting along the x-axis and summed with the control input. The simulation results highlight the comparative efficiency of the optimization methods and demonstrate the robustness of the selected controller in maintaining stability and accuracy under wind-induced perturbations.
1. Introduction
Quadrotors have become essential tools in various real-world applications, such as aerial inspection, emergency response, and precision agriculture, where agility and reliable navigation are critical. One of the persistent challenges is achieving accurate trajectory tracking under external disturbances, especially wind gusts, which can cause significant deviations from planned paths. While linear control strategies, such as PID or LQR, are often used due to their simplicity, they generally fail to ensure performance when dealing with the nonlinear and coupled dynamics of quadrotors, especially in aggressive maneuvers or uncertain environments. In contrast, nonlinear techniques like backstepping control offer better stability guarantees and are well-suited to handle the system’s nonlinearities explicitly. Artificial intelligence-based controllers, such as those relying on neural networks or fuzzy logic, have also shown promise in the literature for adaptive or data-driven control. However, their practical deployment can be limited by training requirements, a lack of interpretability, and higher computational demands, especially on onboard systems. In this work, we propose to enhance the performance of a backstepping-based controller through an offline optimization of its gains using various metaheuristic algorithms. Rather than introducing additional model complexity, our goal is to identify the most suitable optimization strategy that improves tracking accuracy and convergence speed, while keeping the controller simple and implementable. Among the compared strategies, the most effective one is then tested under input-level wind disturbances to evaluate its robustness. It is important to note that wind perturbations are applied only to the best-performing controller, not to the entire comparison set. In [1], a detailed mathematical model of quadrotor dynamics is formulated using the Newton–Euler method. This model serves as the foundation for implementing a Proportional–Integral–Derivative (PID) control strategy to ensure that the UAV maintains its desired flight path and remains stable against environmental disturbances. An optimized Linear Quadratic Regulator (LQR) controller is developed for controlling the 3-DOF quadrotor “Quanser,” with the controller gains calculated using various metaheuristic algorithms, including Particle Swarm Optimization (PSO), Flower Pollination Algorithm (FPA), and Ant Colony Optimization (ACO) [2]. Different application scenarios for UAVs demand varied functionalities and performance requirements. Adapting control algorithms to meet these scenario-specific needs is highly valuable. PID heuristic and fuzzy PID heuristic algorithms are compared under different operational conditions [3]. To address the external disturbances and model uncertainties affecting quadrotor UAVs during flight, an adaptive non-singular terminal sliding mode controller with disturbance compensation is introduced in [4]. A high-precision algorithm based on multi-sensor data fusion and an optimized Extended Kalman Filter (EKF) was designed and applied to evaluate the flight attitude of quadrotor aircraft [5]. Research in [6] presents an intelligent control framework for an experimental UAV featuring an unconventional inverted V-tail design. A cascade control structure using six PID controllers was proposed to control the 6-DOF UAV quadcopter, ensuring precise altitude and angular position control while maintaining flight balance and stability [7]. Paper [8] addresses the problem of quadrotor motion control under model disturbances and uncertainties by employing adaptive reinforcement learning-based control techniques. A hybrid control strategy that integrates linear active disturbance rejection control (LADRC) with sliding mode control (SMC) was proposed to mitigate uncertainties and external disturbances in fixed-wing UAV attitude control [9]. The quadcopter dynamic system in [10] is controlled using a Radial Basis Function Neural Network (RBFNN), with its performance tested under external disturbances through simulation. A deep reinforcement learning framework was introduced, guided by Multi-PID Self-Attention, to improve the training efficiency and adaptability of quadrotor control algorithms to dynamic environments [11]. Nonlinear modeling of the quadcopter was conducted in [12], leading to the design of a robust backstepping controller capable of executing complex maneuvers. A stable adaptive PID-like control scheme was proposed for quadrotor UAV systems, where the controller dynamically adjusts its gains through an adaptation process to approximate an ideal controller [13]. A robust and simple adaptive control framework was introduced with minimal parameter estimation for trajectory tracking in quadrotors under parametric variations and environmental disturbances [14]. To tackle the challenges posed by external wind disturbances and internal noise, a real-time wind speed fitting algorithm and a wind field model were developed, accommodating varying wind conditions such as turbulence and wind shear [15]. Quadrotor control is divided into two loops in the study by [16]: an outer loop for the positional coordinates managed by linear active disturbance rejection controllers (ADRC), and an inner loop for the orientation variables handled by robust PID controllers. A novel control strategy was proposed by [17] for quadrotor UAV suspension transportation systems, addressing nonlinear and underactuated dynamics to achieve precise positioning, attitude control, and anti-swing capabilities. In [18], a finite-time fractional-order sliding mode controller with integral error action (FISMC) was designed to ensure a rapid convergence of all system states to the desired performance levels. A Universal (U)-control method, enhanced with dynamic inversion, was proposed for tracking operations in multiple-input multiple-output (MIMO) quadrotor systems [19]. Research by [20] reviewed the current state of quadrotor drone control using deep learning-based PID algorithms, offering valuable insights for researchers, developers, and industry stakeholders. Also, numerous control strategies were reviewed in [21] to address the various challenges encountered by UAVs, with a specific focus on quadrotor systems. The quadrotor was modeled and simulated using the Newton–Euler formula combined with sliding mode control (SMC) to enhance control accuracy under external magnetic disturbances [22]. Article [23] outlines the motion mechanics of four-rotor UAVs, as well as the resistance mechanisms against wind disturbances and the differences between traditional PID and fuzzy PID control, offering recommendations for future UAV PID algorithms. A Koopman-based control system for quadrotors was proposed, featuring an environmental selector to handle noisy operational conditions [24]. This research looks into using a PID controller to control a quadrotor. This mathematical model is based on the Euler–Lagrange method. Nonlinearities, coupling, and underactuation constraints made it challenging to design the controller for this model using traditional methods [25]. Paper [26] proposed a nonlinear, robust, adaptive control technique that is capable of compensating for actuator faults and gyroscopic effects, ensuring asymptotic convergence of tracking errors. In [27], an adaptive super-twisting controller that guarantees finite-time convergence and strong robustness against external disturbances was developed, validated through both simulation and real-time experiments. This used a deep adaptive trajectory tracking (DATT) strategy, combining reinforcement learning with adaptive estimation to enable robust trajectory following under large perturbations [28]. Meanwhile, article [29] investigated the use of spiking neural networks (SNNs) for quadrotor trajectory control, providing a biologically inspired and efficient alternative for precision flight. Finally, an embedded nonlinear model predictive control (NMPC) framework was presented for aggressive trajectory tracking in nano-quadrotors, demonstrating its effectiveness in highly dynamic real-world scenarios [30]. Furthermore, integral terminal sliding mode control was used to enhance robustness in underactuated UAVs in [31]. Additionally, intelligent optimal control methods have been investigated in energy systems [32], and observer-based feedback linearization has been designed for UAV stabilization [33]. In this context, our work is motivated by the need for a control strategy that is both robust to wind disturbances and easy to implement, while providing high tracking precision and a low response time. We focus on backstepping control due to its strong theoretical guarantees for nonlinear systems and its suitability for underactuated platforms like quadrotors. However, manual tuning of backstepping gains is non-trivial and sensitive to environmental changes. Therefore, the main contributions of this study are as follows: The development of a complete nonlinear dynamic model of a quadrotor using the Newton–Euler formalism served as a simulation platform for control design and analysis. We also designed a backstepping controller adapted to this model, aiming to improve stability and trajectory tracking under normal flight conditions. We also integrated three metaheuristic optimization algorithms—Gray Wolf Optimization (GWO), Particle Swarm Optimization (PSO), and Flower Pollination Algorithm (FPA)—to optimally tune the gains of the backstepping controller based on tracking performance. Comprehensive simulation-based comparisons of the three optimized controllers, in terms of their tracking accuracy, response time, and control effort under nominal conditions, were also conducted. We also conducted a focused robustness evaluation of the best-performing controller by introducing a wind disturbance that was modeled as an additive force that acted on the x-axis thrust input, simulating wind that was aligned with the quadrotor’s motion. The originality of this work lies in two main contributions: A comparative study of metaheuristic optimization methods that are applied to a nonlinear backstepping controller, which has received limited attention in previous literature. This highlights how different tuning approaches affect the controller’s performance in terms of accuracy and convergence. A robustness analysis under wind disturbances was also introduced at the input level (rather than modeling wind in the system’s dynamics), applied exclusively to the controller tuned by the best-performing optimization method. This simplified yet realistic approach allows for practical validation of the controller’s robustness without adding complexity to the model. Overall, the proposed methodology offers a pragmatic compromise between nonlinear control performance and optimization flexibility, making it suitable for onboard applications that require reliable, real-time performance without excessive computational burden. The remainder of this paper is structured as follows: Section 2 presents the physical modeling and mathematical equations of the quadrotor. Section 3 details the design of the backstepping controller. Section 4 introduces the three optimization algorithms used for gain tuning. Section 5 presents the simulation results, performance comparisons, and robustness analyses under wind disturbance. Finally, the conclusions and future work intentions are discussed in Section 6.
2. Quadrotor Modeling
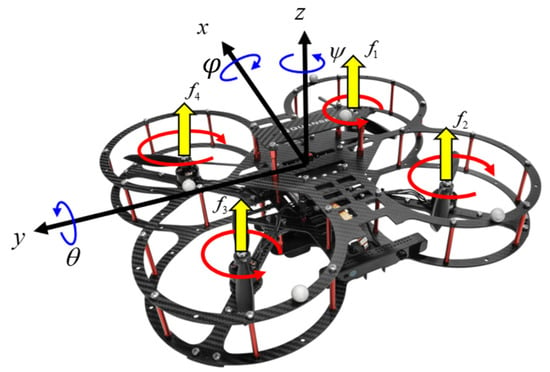
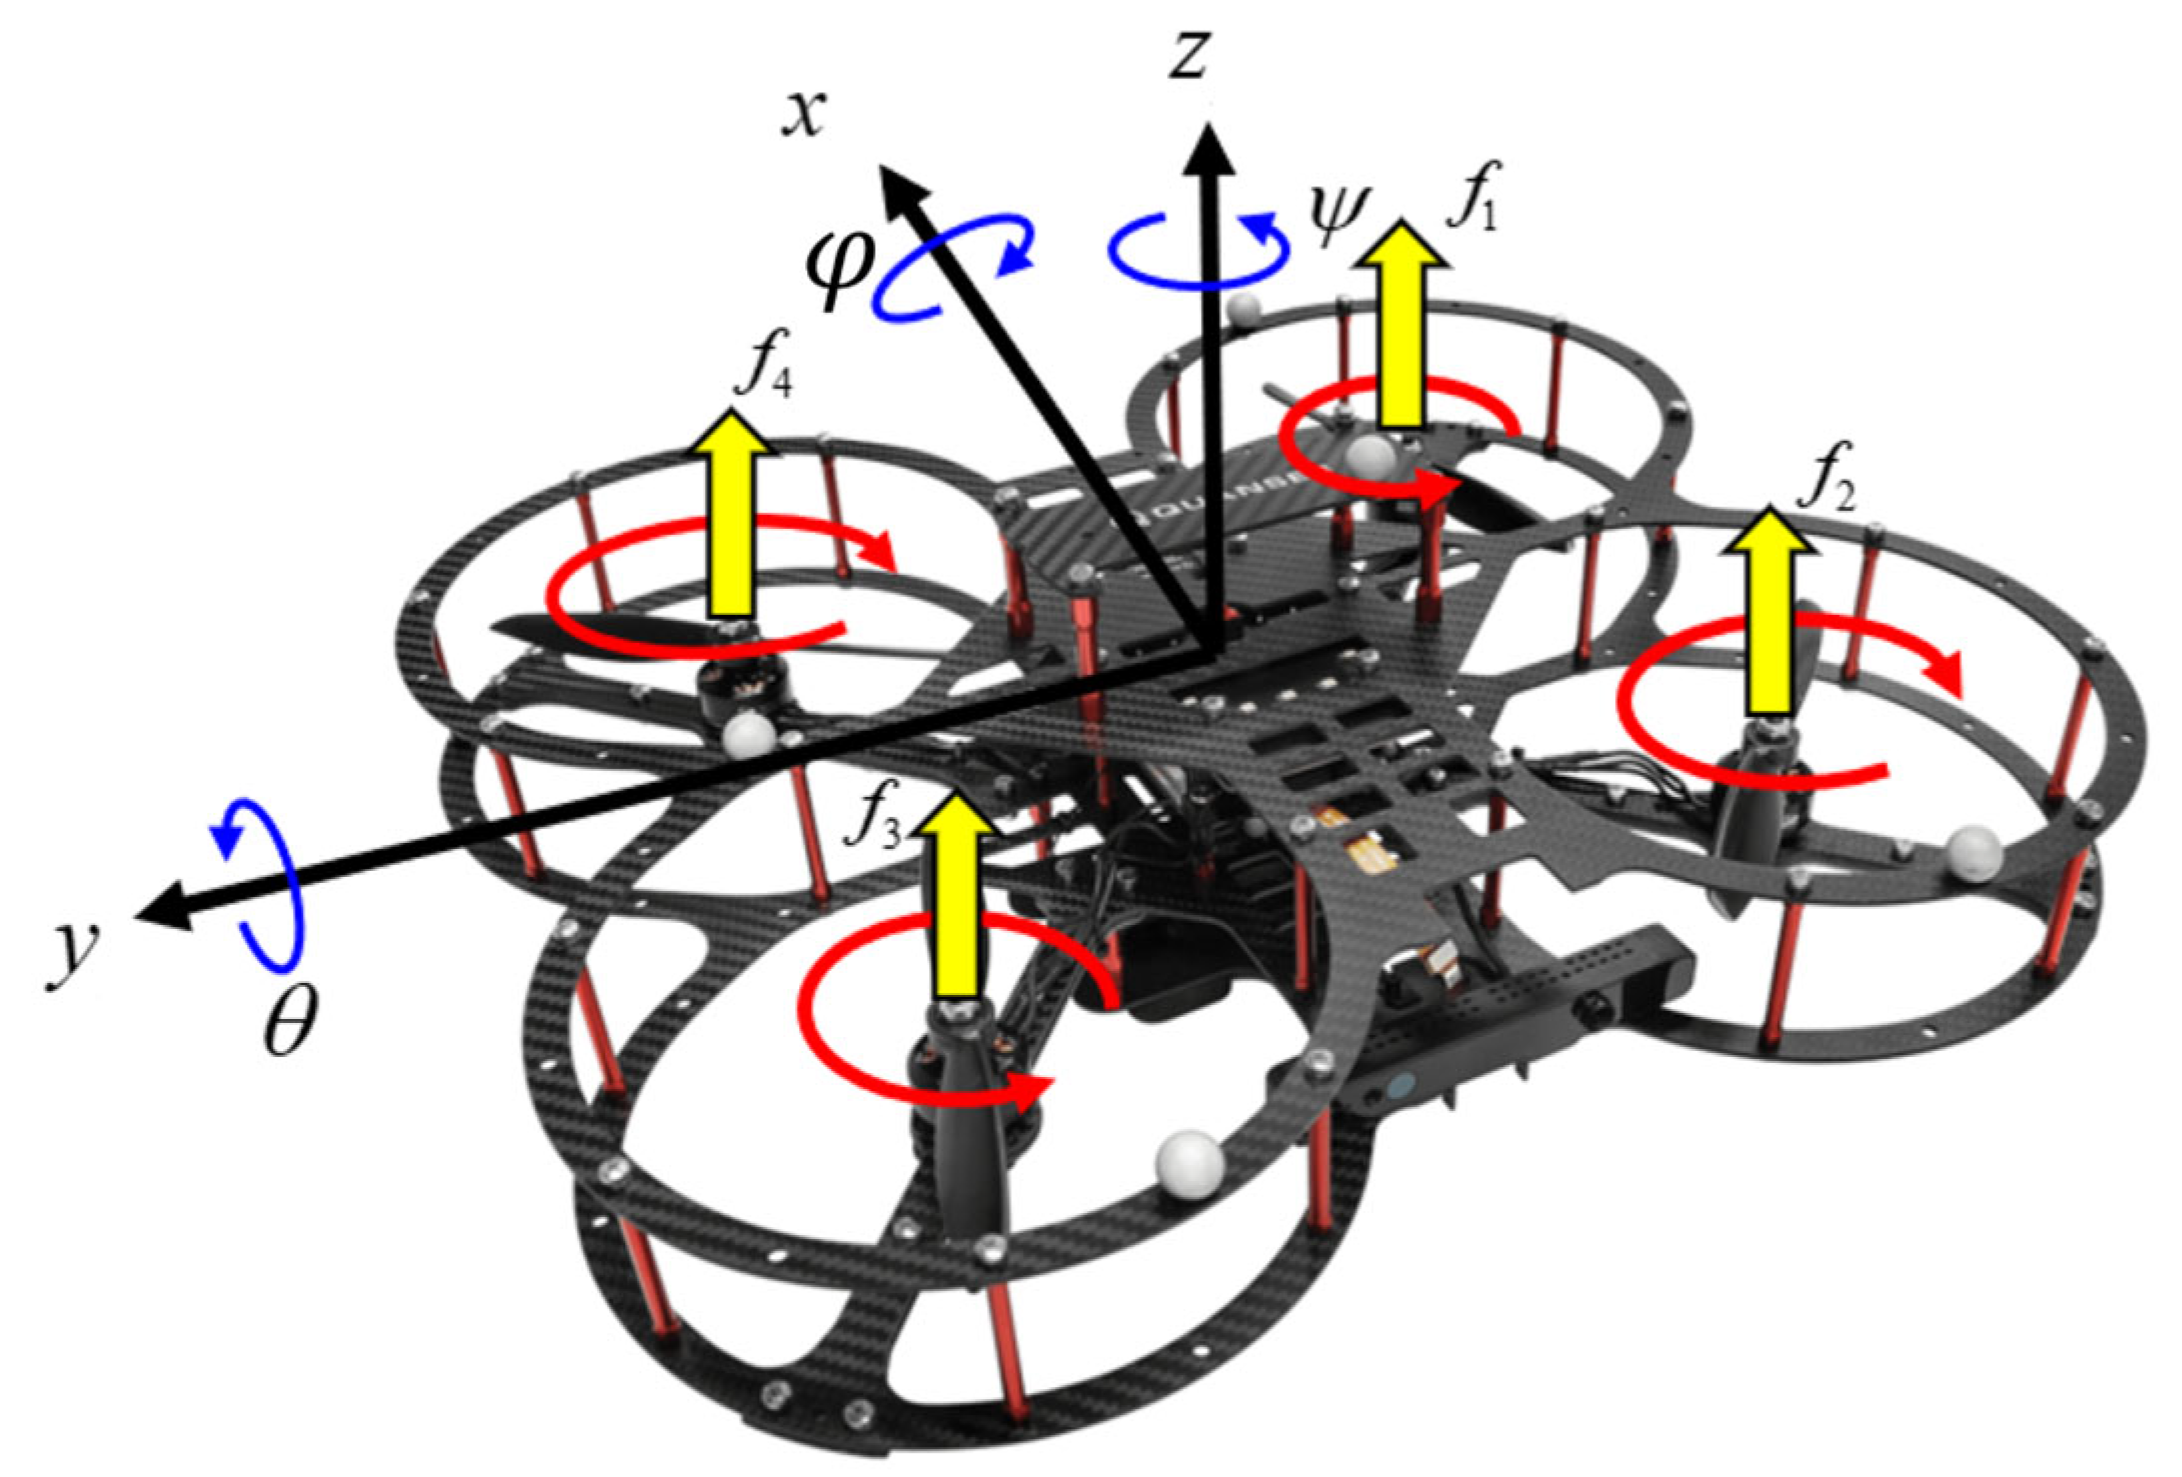
The quadrotor drone is an aerial robot that consists primarily of four motors mounted onto a symmetrical frame that is equipped with a motion controller and powered by a battery supplying electrical energy to the motors (Figure 1).
Figure 1.
Projecting degrees of freedom and the forces created by the motors onto the quadrotor.
Mathematically, the quadrotor can be modeled by the following nonlinear state space model [34]:
where
3. Assumptions
The quadrotor is considered to be a rigid, symmetric body, and its mass and inertia properties remain constant during the flight.
Actuator saturation, motor delay, and sensor noise are not explicitly modeled but are implicitly assumed to be negligible or within the acceptable limits.
The roll () and pitch () angles are constrained within the range of −90° to +90°, ensuring the validity of the trigonometric simplifications and avoiding gimbal lock.
All system states (i.e., positions, velocities, and attitudes) are assumed to be fully measurable and available for feedback.
The robustness test of the selected method is done by wind disturbance, and it is applied to the quadrotor by adding a variable and bounded signal to the signal of the force concerned by the movement on one of the x or y axes to ensure a disturbance of the horizontal movement.
The backstepping control was designed based on a known and ideal nonlinear model of the quadrotor without unmodeled dynamics.
4. Control Method
Backstepping control is a recursive design method that is used in nonlinear control systems, particularly for systems with complex dynamics. It involves breaking down the system’s state variables into simpler subsystems, designing controllers for each subsystem, and “stepping back” to form a global control law. This technique ensures stability and desired performance by iteratively stabilizing each subsystem and combining them into a comprehensive control strategy.
We consider the following subsystem of the quadrotor dynamics, describing one degree of freedom (pitch ):
Let be the pitch angle and be its angular velocity. The control objective is to ensure that tracks a desired trajectory .
Using the backstepping technique, the goal is to design to stabilize the tracking error dynamics.
Starting from the error derivatives:
The control input is designed to cancel the nonlinear term and stabilize the error dynamics with the chosen gains and Specifically, consider the following error dynamics target:
This corresponds to a stable second-order error dynamics. Re-arranging for , we get:
Substituting :
Solving for :
Consider the Lyapunov function:
Its derivative is:
Using the target error dynamics:
Substituting :
Grouping terms:
To ensure , the following condition must hold:
Since the control gains and are selected through optimization (with ), the term ( is negative, and the overall expression is guaranteed to remain non-positive for all tracking error values. As the tracking errors and converge toward zero under these conditions, the stability of the closed-loop system is ensured. This confirms that the proposed controller guarantees asymptotic convergence of the pitch angle to its desired trajectory.
Therefore, the final control law used to stabilize the pitch subsystem is:
The control laws for the other degrees of freedom (altitude , roll angle , yaw angle , position and position ) are obtained using the same method:
where
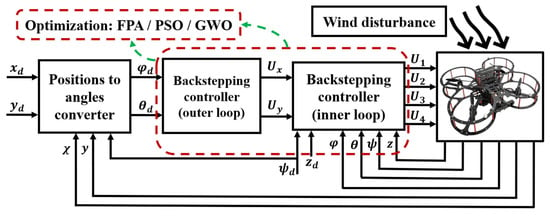
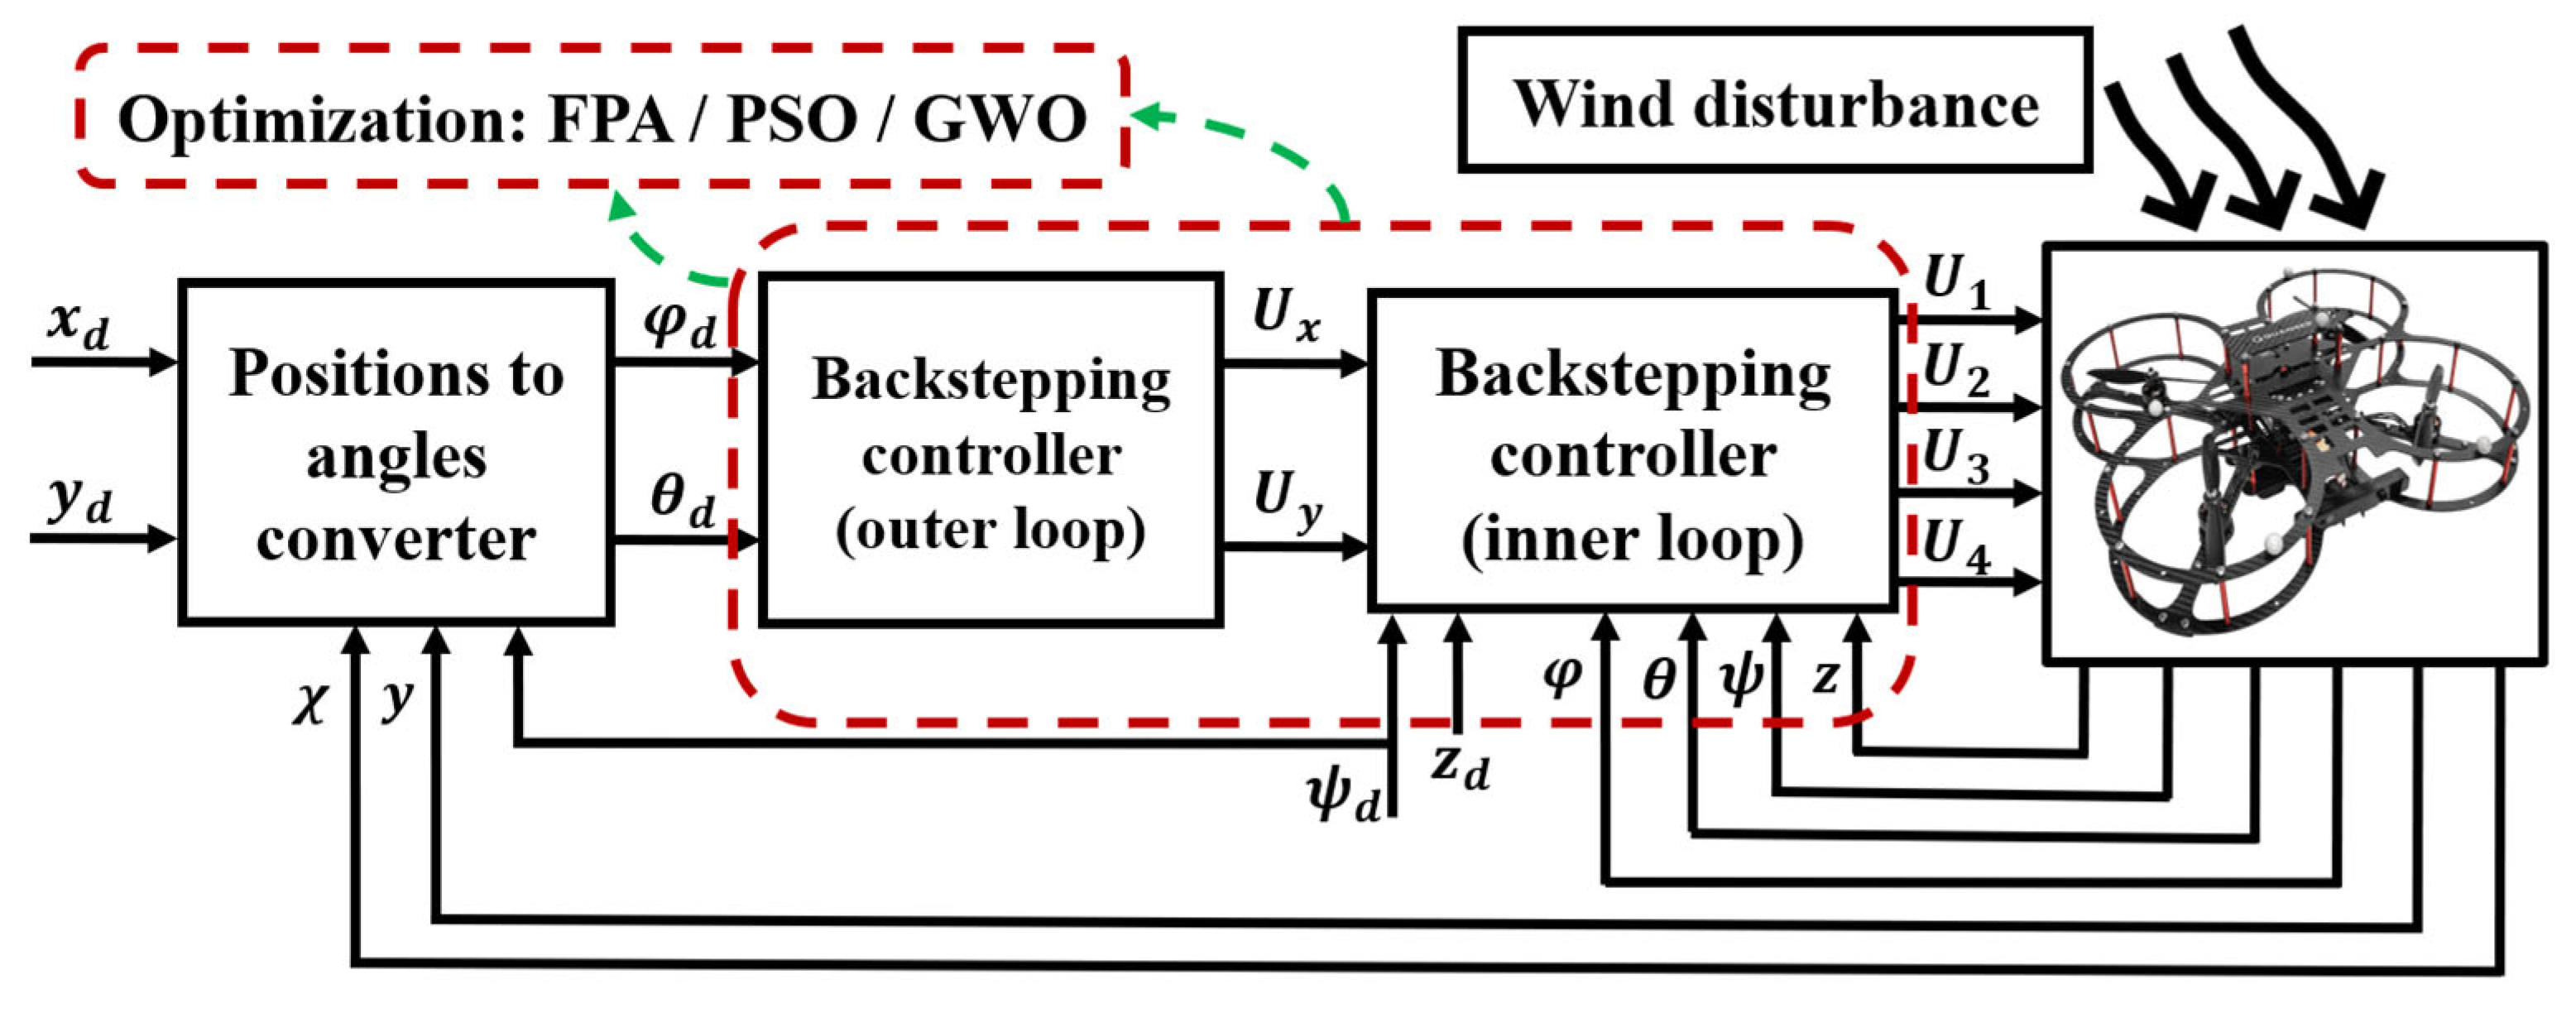
The gain vector is obtained based on various optimizations that calculate new gains, at each iteration, with the goal of minimizing the error between the desired and real variables (Figure 2).
Figure 2.
Optimized backstepping applied to the quadrotor.
Since the system is mathematically coupled, the control of positions and depends on the control of the roll , pitch , and yaw angles, which requires a conversion block that computes the desired roll and pitch angles and (Figure 2).
5. Proposed Controller’s Optimization
In this work, three bio-inspired metaheuristic algorithms are employed to optimize the gain parameters of the backstepping controller. The objective is to minimize the tracking error by finding the optimal set of gains using evolutionary search processes.
5.1. Flower Pollination Algorithm FPA
The FPA is inspired by the pollination behavior of flowering plants, where pollinators like bees and butterflies enable global exploration, while self-pollination represents local exploitation. The global pollination process is modeled using Lévy flights to ensure wide-ranging search capabilities [35]. The update equation of this algorithm is:
where is the current solution , is the global best solution, and is a step size drawn from a Lévy distribution.
Each solution corresponds to a set of backstepping controller gains. The algorithm iteratively moves toward better gain configurations, minimizing a cost function (the integral squared error) by exploiting the search space effectively.
5.2. Gray Wolf Optimization GWO
GWO mimics the leadership hierarchy and hunting strategy of gray wolves. The population is divided into alpha, beta, delta, and omega wolves, with the position updates guided by the best three individuals. The update equation of this algorithm is:
where , and are the top three candidate solutions.
Each wolf represents a candidate gain set. The algorithm guides the population to converge toward the most effective backstepping gains, thereby reducing the integral squared error over iterations.
5.3. Particle Swarm Optimization PSO
PSO is inspired by the social behavior of bird flocks or fish schools. Each particle explores the solution space by adjusting its velocity based on both personal and collective experiences [2]. The update equation of this algorithm is:
where and are the particle’s position and velocity, is its personal best, is the global best, and , and are the algorithm’s parameters with random coefficients and .
Each particle represents a set of backstepping gains. Through iterative learning from its own performance and the swarm’s best performance, PSO refines the gain set to minimize the integral squared error efficiently.
The parameters of each algorithm are shown in Table 1.
Table 1.
Optimization key parameters of each algorithm.
The objective function is the integral squared error, whose equation is:
where is the error between the desired and real position for each degree of freedom, and is the simulation time for each iteration [36]. The proposed objective function is non-convex, which is common in multi-criteria control design problems, especially in nonlinear systems. As a result, metaheuristic algorithms such as PSO, FPA, and GWO are employed to handle the non-convexity and effectively explore the solution space. These algorithms do not guarantee convergence to the global minimum; however, they are widely used for their ability to find satisfactory solutions in complex optimization landscapes. In our case, the optimization process is performed offline, and the best solution—corresponding to the minimal tracking error—is selected and retained. The resulting controller operates in real-time with fixed gains, ensuring reliable and consistent performance during trajectory tracking.
6. Results and Discussion
The simulation results are obtained using the MATLAB/Simulink (2018a) software after simulating the nonlinear model of the quadrotor that was controlled by the developed backstepping controller based on the physical parameters mentioned in Table 2.
Table 2.
Quadrotor’s simulation parameters.
Each optimization method provides its own set of gains (Table 3), which are used by the backstepping controller during the generation of the control laws.
Table 3.
Obtained gains using different optimizations.
The obtained gains do not exceed the value of 13 because the search space for the tested algorithms is defined within the range (0–13) This limitation is imposed to prevent command saturation and, consequently, prevent the saturation of the voltages applied to the quadrotor’s motors. In the theoretical analysis, is considered to be strictly positive () to satisfy the conditions for Lyapunov stability. This assumption ensures the asymptotic convergence of the tracking error. In practice, the value of is tuned using optimization algorithms, as presented in Table 3, to improve the dynamic response of the controller. The gap between the theoretical assumption and the optimized values reflects the need to adapt the controller gains to the real system dynamics while preserving the theoretical stability guarantees.
6.1. Step Response
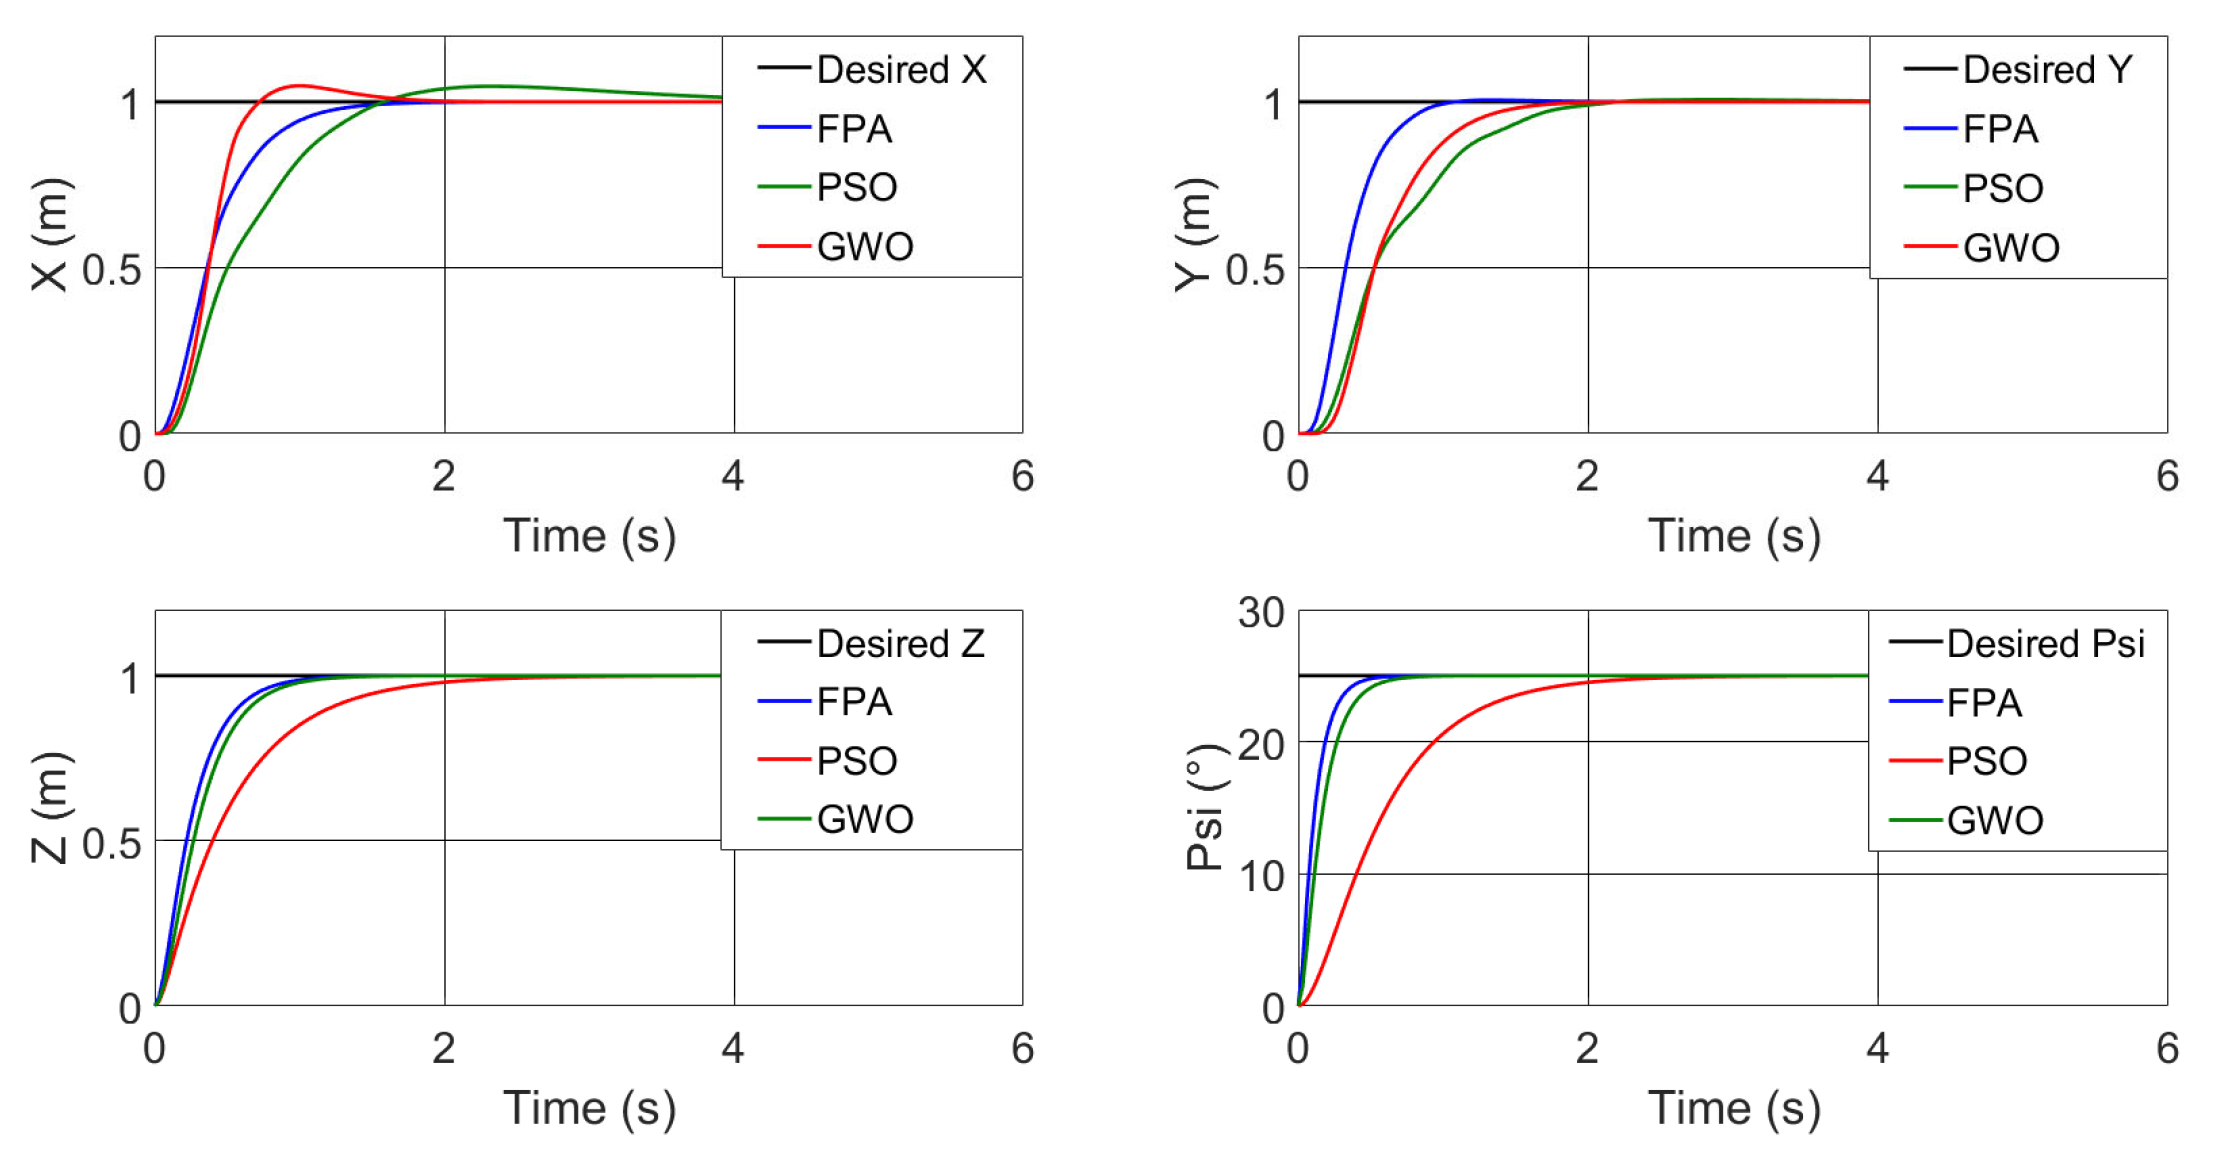
A fixed desired position in 3D with an orientation angle is tested on the system to evaluate its performance, where .
The system’s responses for the desired positions are stable and highly acceptable, as the error tends towards zero for all optimization techniques (Figure 3).
Figure 3.
Step response.
6.2. Comparison
The performance metrics, such as precision, speed, and stability for all positions , , and , are used as criteria for a comparison between the three optimized backstepping controllers (Table 4).
Table 4.
Comparison between proposed optimization results.
Based on the obtained results, all of the optimization methods demonstrate excellent tracking precision. However, the backstepping controller, optimized using the Flower Pollination Algorithm (FPA), outperforms the others, exhibiting the shortest settling time and minimal overshoot, which indicates superior performance in terms of both convergence speed and stability.
6.3. Trajectory Tracking and Robustness Test
The following x, y, and z positions were used to create a desired trajectory (in meters) of an infinity shape, which was tracked by the quadrotor that was controlled using the chosen method (backstepping based on the FPA).
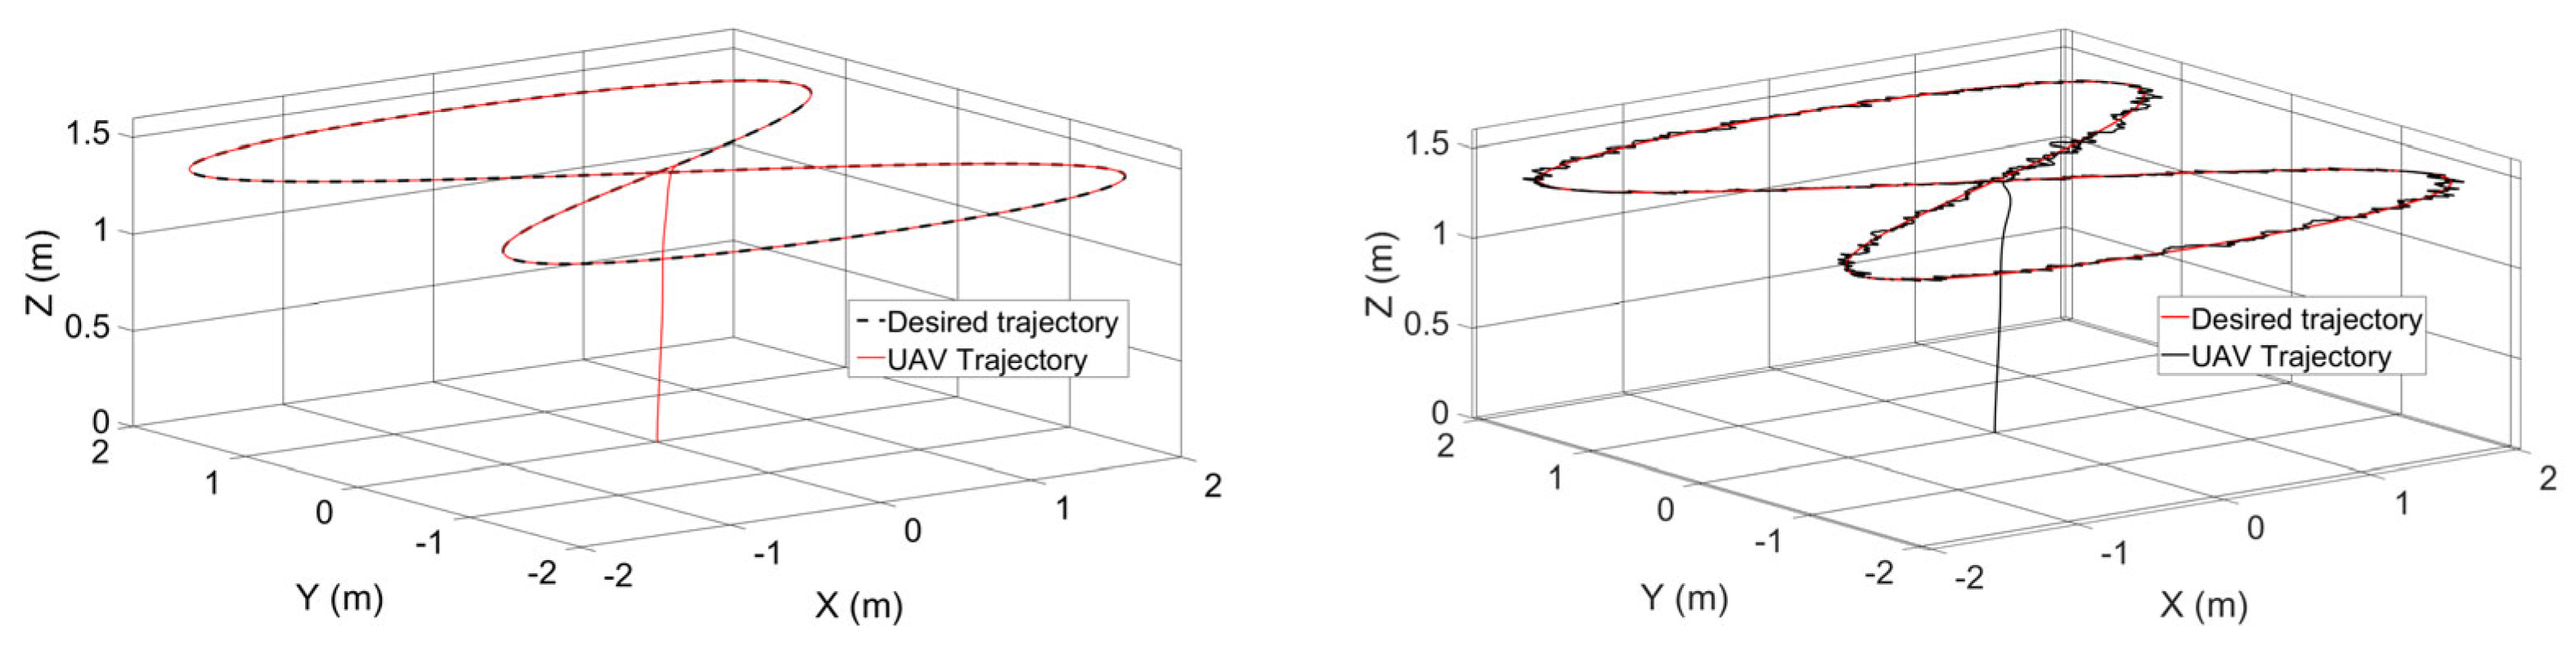
Figure 4 provides a 3D comparison of the quadrotor’s trajectory tracking in the shape of an infinity loop under two conditions. The left subfigure illustrates the trajectory tracking without wind disturbance, where the quadrotor closely follows the desired path with high precision and smooth motion. The right subfigure depicts the tracking performance under wind disturbance. Although the quadrotor experiences slight deviations from the reference path at the moments of disturbance, it consistently returns to the desired trajectory, demonstrating the controller’s robustness and ability to recover from external perturbations without instability or divergence.
Figure 4.
Trajectory tracking in 3D: Without disturbance (left) and under wind disturbance (right).
Another test was performed using the following desired trajectory:
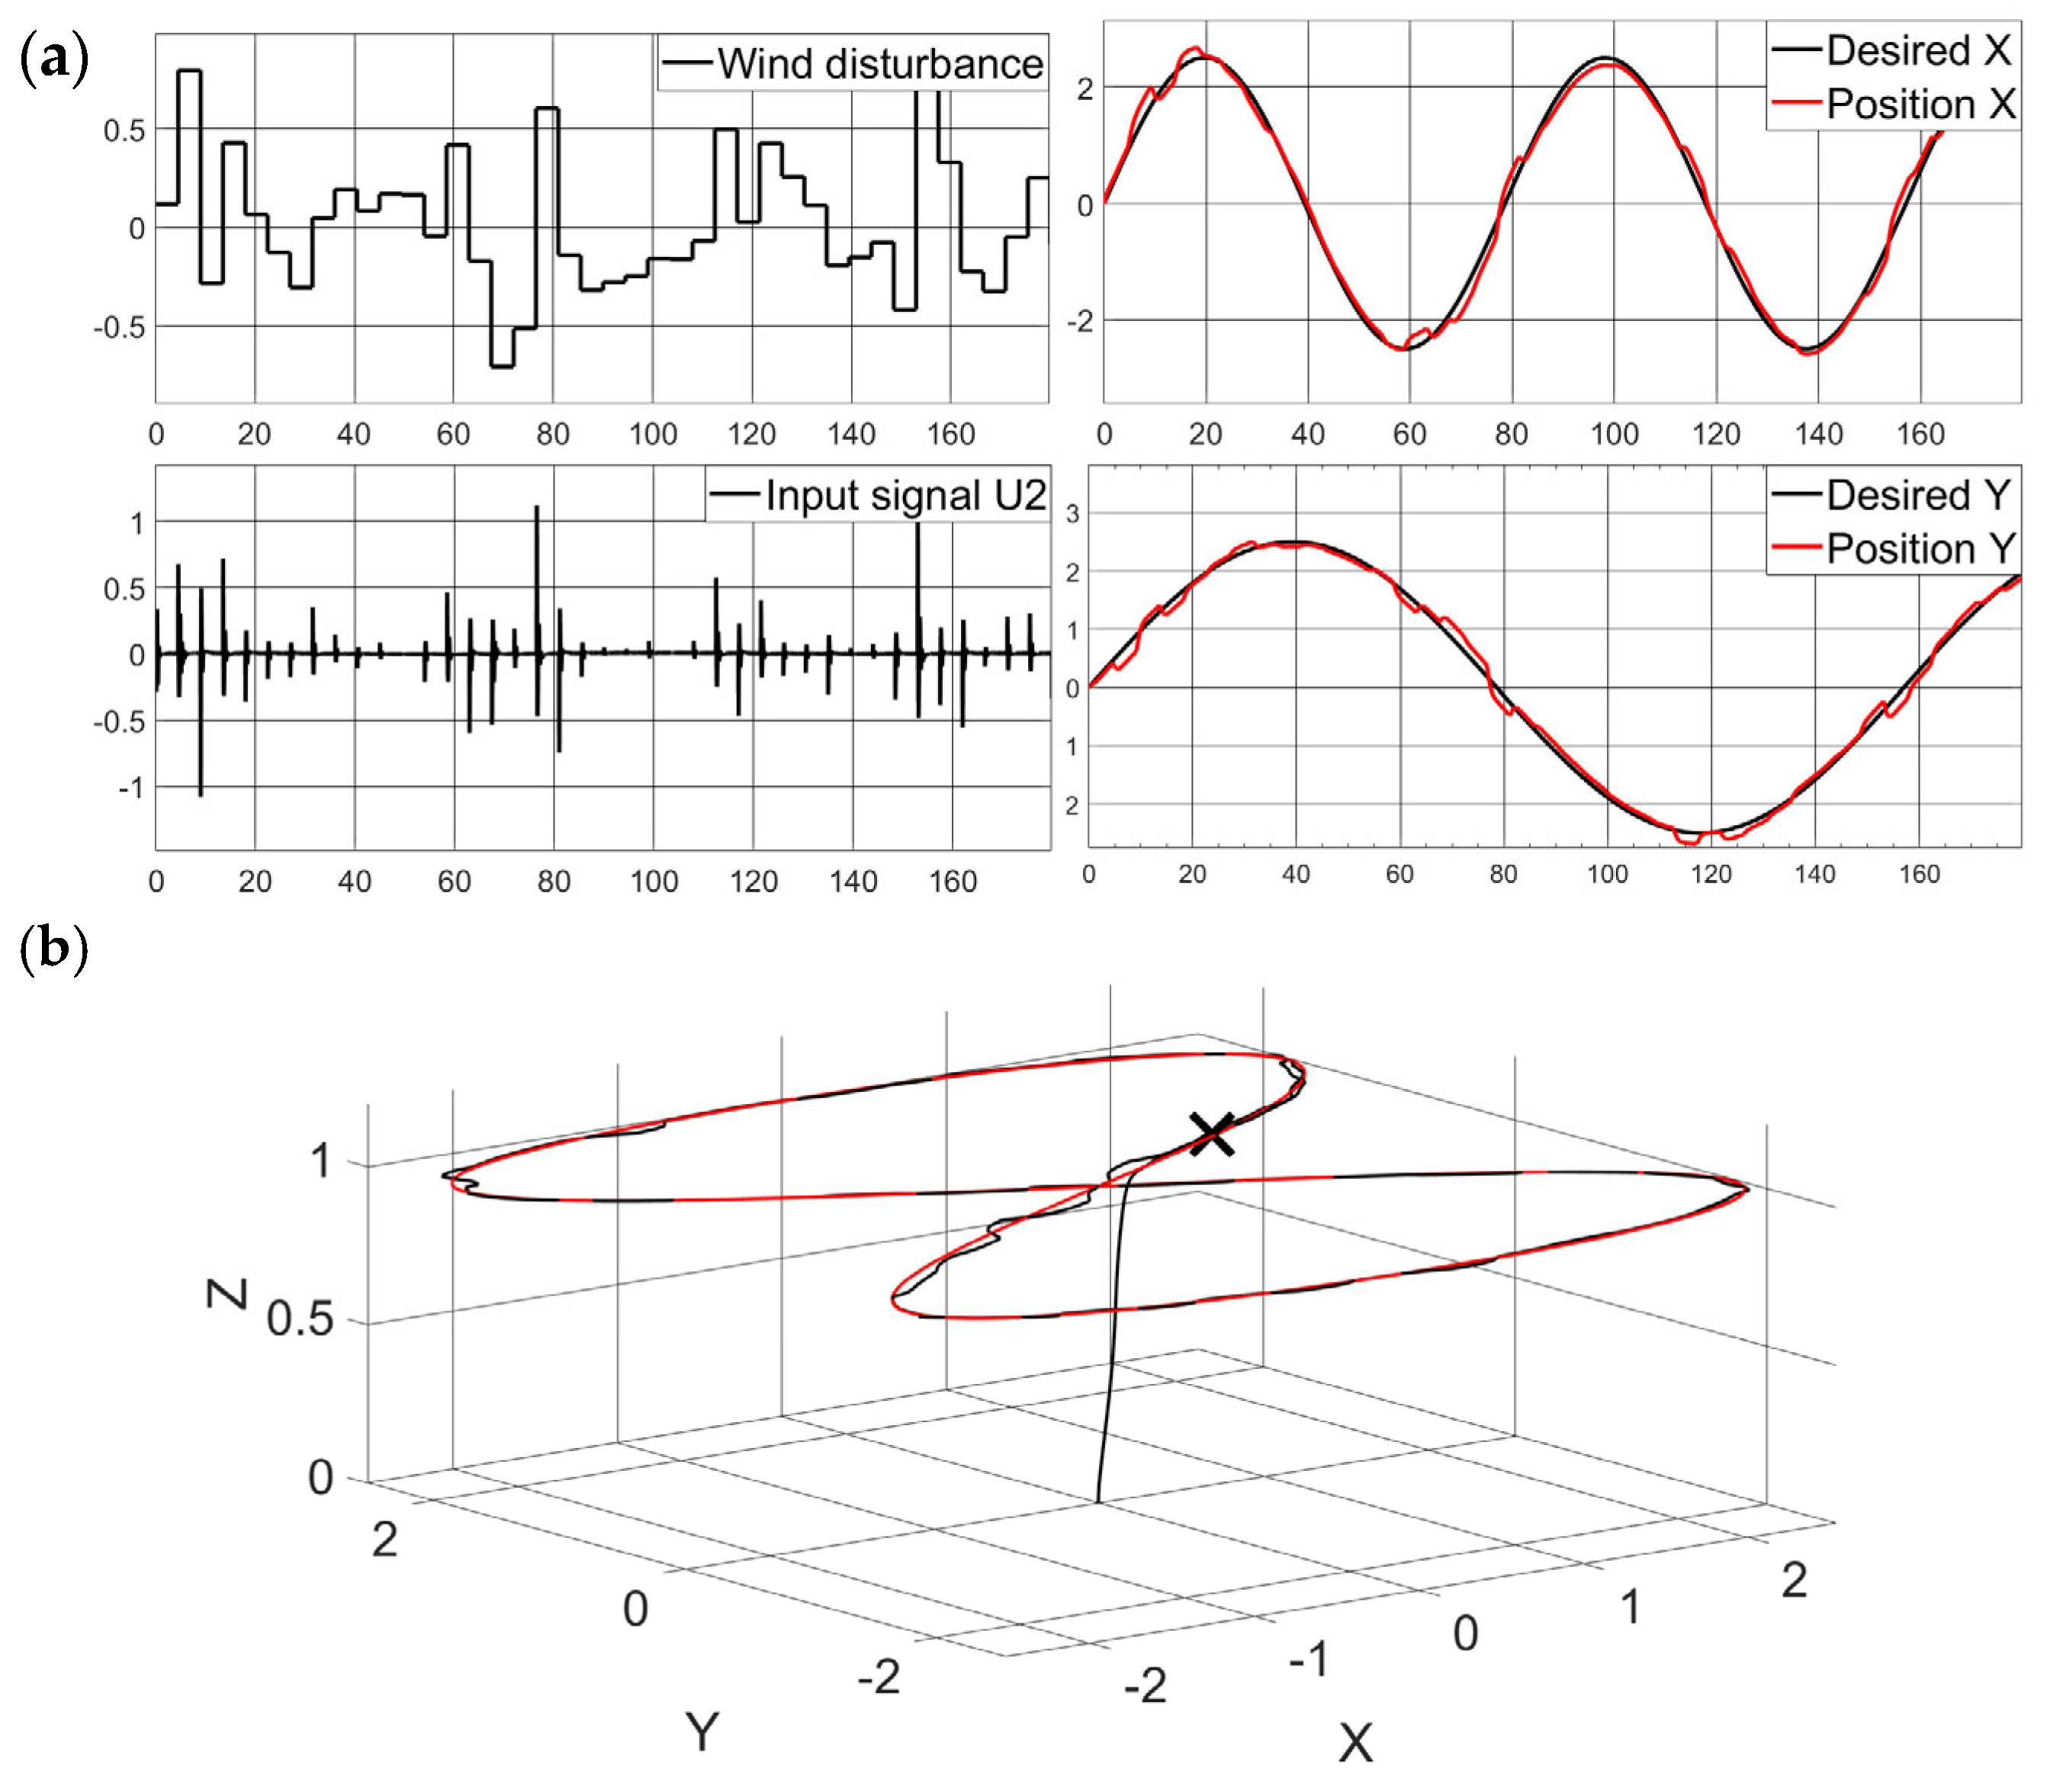
In Figure 5a, four signals are presented: a randomly generated wind disturbance applied at the input level, the resulting control input after disturbance injection, and the quadrotor’s actual () positions. Despite the presence of disturbance, the position signals remain oscillating around their desired sinusoidal references without significant divergence, confirming the controller’s ability to maintain stable tracking performance. In Figure 5b, the 3D trajectory () under wind disturbance is shown. The quadrotor is momentarily perturbed at various instances due to simulated aerial impacts, but quickly returns to its reference trajectory. This visual confirmation further supports the robustness and resilience of the optimized backstepping control strategy in the face of realistic external disturbances.
Figure 5.
Trajectory tracking under wind disturbance: (a) Wind disturbance signal, control signal after disturbance, positions (x, y) under wind disturbance; (b) 3D presentation under wind disturbance.
7. Conclusions
This paper presented a backstepping controller designed for the trajectory tracking of a quadrotor drone. The controller’s gains were optimized using three metaheuristic algorithms, such as Gray Wolf Optimization (GWO), Particle Swarm Optimization (PSO), and Flower Pollination Algorithm (FPA), each producing distinct performance outcomes. The controllers were evaluated based on their stability, accuracy, and response speeds. The most effective method was further tested under wind disturbances to assess its robustness. The results are promising, highlighting both the effectiveness and resilience of the proposed control approach. Additionally, this study offers valuable insights into the role of optimization in enhancing the performance of nonlinear controllers for dynamic systems through comparative analysis.
Author Contributions
Conceptualization, I.B.G. and L.A.; methodology, I.B.G. and L.A.; software, I.B.G., O.L. and A.H.D.; validation, I.B.G. and L.A.; investigation, I.B.G. and L.A.; writing—original draft preparation, I.B.G.; writing—review and editing, L.A.; visualization, I.B.G., L.A., O.L. and A.H.D.; supervision, L.A.; project administration, L.A. All authors have read and agreed to the published version of the manuscript.
Funding
This research received no external funding.
Institutional Review Board Statement
Not applicable.
Informed Consent Statement
Not applicable.
Data Availability Statement
The original contributions presented in this study are included in the article. Further inquiries can be directed to the corresponding author.
Conflicts of Interest
The authors declare no conflicts of interest.
References
- Liu, Y. Modelling and simulation of quadcopter UAV based on PID control. Appl. Comput. Eng. 2024, 75, 2721–2755. [Google Scholar] [CrossRef] [Scilit]
- Ghiloubi, I.B.; Abdou, L.; Lahmar, O.; Dahnoun, I. 3 DOF Quanser’s Quadrotor control using LQR based on PSO, FPA & ACO with input saturation. In Proceedings of the 2023 IEEE 11th International Conference on Systems and Control (ICSC), Sousse, Tunisia, 18–20 December 2023. [Google Scholar] [CrossRef] [Scilit]
- Dong, J. Performance comparison and analysis of traditional PID and fuzzy PID control applied to UAV. J. Phys. Conf. Ser. 2023, 2649, 012001. [Google Scholar] [CrossRef] [Scilit]
- Sang, H.; Zheng, F.; Huang, F.; Zhang, S. Quadrotor UAV Trajectory Tracking Control Based on Adaptive Non-singular Terminal Sliding Mode. J. Electr. Syst. 2024, 20, 929–939. [Google Scholar] [CrossRef] [Scilit]
- Zhou, R. Research on High-precision Algorithm for Flight Attitude Evaluation of Quadrotor Aircraft. Trans. Comput. Sci. Intell. Syst. Res. 2024, 8, 29–34. [Google Scholar] [CrossRef] [Scilit]
- Ud Din, A.F.; Mir, I.; Gul, F.; Mir, S.; Saeed, N.; Althobaiti, T.; Abbas, S.M.; Abualigah, L. Deep Reinforcement Learning for Integrated Non-Linear Control of Autonomous UAVs. Processes 2022, 10, 1307. [Google Scholar] [CrossRef] [Scilit]
- Mien, T.; Tu, T.; Vo, V.-A. Cascade PID control for altitude and angular position stabilization of 6-DOF UAV quadcopter. Int. J. Robot. Control Syst. 2024, 4, 814–831. [Google Scholar] [CrossRef] [Scilit]
- Leitão, D.; Cunha, R.; Lemos, J. Adaptive Control of Quadrotors in Uncertain Environments. Eng 2024, 5, 544–561. [Google Scholar] [CrossRef] [Scilit]
- Wang, B.; Yan, Y.; Xiong, X.; Han, Q.; Li, Z. Attitude Control of Small Fixed−Wing UAV Based on Sliding Mode and Linear Active Disturbance Rejection Control. Drones 2024, 8, 318. [Google Scholar] [CrossRef] [Scilit]
- Darwito, P. Control System for Quadcopter UAV based SMC-RBFNN with External Disturbance. E3S Web Conf. 2024, 482, 03004. [Google Scholar] [CrossRef] [Scilit]
- Ren, Y.; Zhu, F.; Sui, S.; Yi, Z.; Chen, K. Enhancing Quadrotor Control Robustness with Multi-Proportional–Integral–Derivative Self-Attention-Guided Deep Reinforcement Learning. Drones 2024, 8, 315. [Google Scholar] [CrossRef] [Scilit]
- Karahan, M. Nonlinear Modelling and Robust Backstepping Control of a Quadcopter in Aggressive Maneuvering. Stud. Inform. Control 2024, 33, 29–38. [Google Scholar] [CrossRef] [Scilit]
- Boubakir, A.; Souanef, T.; Labiod, S.; Whidborne, J. A Robust Adaptive PID-like Controller for Quadrotor Unmanned Aerial Vehicle Systems. Aerospace 2024, 11, 980. [Google Scholar] [CrossRef] [Scilit]
- Maaruf, M.; Abubakar, A.; Gulzar, M. Adaptive backstepping and sliding mode control of a quadrotor. J. Braz. Soc. Mech. Sci. Eng. 2024, 46, 630. [Google Scholar] [CrossRef] [Scilit]
- Ma, Q.; Wu, Y.; Muhammad Usman, S.; Yan, Y.; Wang, J.; Yang, L.; Yan, F.; Yan, L. Deep Reinforcement Learning-Based Wind Disturbance Rejection Control Strategy for UAV. Drones 2024, 8, 632. [Google Scholar] [CrossRef] [Scilit]
- Ramirez-Neria, M.; Luviano-Juárez, A.; González-Sierra, J.; Ramírez-Juárez, R.; Aguerrebere, J.; Hernandez-Martinez, E. Active Disturbance Rejection Control for the Trajectory Tracking of a Quadrotor. Actuators 2024, 13, 340. [Google Scholar] [CrossRef] [Scilit]
- Zhu, B.; Wang, D. Nonlinear Adaptive Control Design for Quadrotor UAV Transportation System. Drones 2024, 8, 420. [Google Scholar] [CrossRef] [Scilit]
- Abdussamad, M.F.; Abubakar, S.I.; Lawal, M.I.; Mukhtar, I.B.; Muhammad, A.B. Adaptive Control of Quadrotor with Neural disturbance Estimator. Glob. J. Res. Eng. Comput. Sci. 2024, 4, 88–101. [Google Scholar] [CrossRef]
- Lone, A.; Zhu, Q.; Nemati, H.; Mercorelli, P. Dynamic Inversion-Enhanced U-Control of Quadrotor Trajectory Tracking. Drones 2024, 8, 599. [Google Scholar] [CrossRef] [Scilit]
- He, X. A review of research on the control of quadrotor UAVs based on deep learning PID algorithm. Appl. Comput. Eng. 2024, 45, 129–133. [Google Scholar] [CrossRef] [Scilit]
- Al-Husnawy, T.; Al-Ghanimi, A. A review of control methods for quadrotor UAV. Kufa J. Eng. 2024, 15, 98–124. [Google Scholar] [CrossRef] [Scilit]
- Nguyen, V.-C.; Nguyen, M.; Tran, H.; Mien, T.; La, H.; Nguyen, H. Trajectory Tracking Control for a Quadcopter under External Disturbances. Eng. Technol. Appl. Sci. Res. 2024, 14, 17620–17628. [Google Scholar] [CrossRef] [Scilit]
- Qi, Z. On the use of PID control to improve the stability of the quad-rotor UAV. Appl. Comput. Eng. 2024, 49, 31–36. [Google Scholar] [CrossRef] [Scilit]
- Oh, Y.; Lee, M.; Moon, J. Koopman-Based Control System for Quadrotors in Noisy Environments. IEEE Access 2024, 12, 71675–71684. [Google Scholar] [CrossRef] [Scilit]
- Hasseni, S.-E.-I.; Abdou, L.; Glida, H. Parameters tuning of a quadrotor PID controllers by using nature-inspired algorithms. Evol. Intell. 2021, 14, 61–73. [Google Scholar] [CrossRef] [Scilit]
- Kidambi, G.K.; Annamalai, A.; Sahu, R.; Kumar, P. Nonlinear robust adaptive control for quadrotors under actuator faults and gyroscopic effects. Aerosp. Sci. Technol. 2023, 142, 108223. [Google Scholar] [CrossRef] [Scilit]
- Rao, S.S.; Krishnakumar, R.; Sundar, R. Adaptive super-twisting control for quadrotor trajectory tracking with external disturbances. ISA Trans. 2023, 141, 382–395. [Google Scholar] [CrossRef] [Scilit]
- Huang, H.; Wu, Q.; Song, S.; Yuan, Z. Deep adaptive trajectory tracking control for quadrotors using reinforcement learning. In IEEE Transactions on Neural Networks and Learning Systems; Early Access; IEEE Xplore: Piscataway, NJ, USA, 2023. [Google Scholar]
- Oniz, Y. Trajectory Control of Quadrotors via Spiking Neural Networks. Electronics 2024, 13, 3319. [Google Scholar] [CrossRef] [Scilit]
- Kazim, M.; Sim, H.; Shin, G.; Hwang, H.; Kim, K.K.K. Aggressive Trajectory Tracking for Nano Quadrotors Using Embedded Nonlinear Model Predictive Control. In Intelligent Autonomous Systems 18; Lee, S.G., An, J., Chong, N.Y., Strand, M., Kim, J.H., Eds.; Lecture Notes in Networks and Systems; Springer: Cham, Switzerland, 2024; Volume 795, pp. 317–332. [Google Scholar] [CrossRef] [Scilit]
- Ullah, S.; Alghamdi, H.; Algethami, A.A.; Alghamdi, B.; Hafeez, G. Robust control design of under-actuated nonlinear systems: Quadcopter unmanned aerial vehicles with integral backstepping integral terminal fractional-order sliding mode. Fractal Fract. 2024, 8, 412. [Google Scholar] [CrossRef] [Scilit]
- Alghamdi, H.; Khan, T.A.; Hua, L.-G.; Hafeez, G.; Khan, I.; Ullah, S.; Khan, F.A. A novel intelligent optimal control methodology for energy balancing of microgrids with renewable energy and storage batteries. J. Energy Storage 2024, 90, 111657. [Google Scholar] [CrossRef] [Scilit]
- Irfan, S.; Zhao, L.; Ullah, S.; Javaid, U.; Iqbal, J. Differentiator- and observer-based feedback linearized advanced nonlinear control strategies for an unmanned aerial vehicle system. Drones 2024, 8, 527. [Google Scholar] [CrossRef] [Scilit]
- Abitha, A.M. Modelling of quad-rotor dynamics and Hardware-in-the-Loop simulation. Int. J. Eng. Technol. 2024, 13, 349–359. [Google Scholar]
- Ghiloubi, I.B.; Abdou, L.; Lahmar, O. Adjusted linear quadratic regulator-proportional-derivative control of Quanser’s three degrees of freedom helicopter based on flower pollination algorithm under external disturbances. IAES Int. J. Robot. Autom. 2024, 13, 432–433. [Google Scholar] [CrossRef] [Scilit]
- Ghiloubi, I.B.; Abdou, L.; Lahmar, O. PD-LQR control of 3DOF helicopter using FPA optimization. In Proceedings of the 2023 International Conference on Control, Automation and Diagnosis (ICCAD), Rome, Italy, 10–12 May 2023. [Google Scholar] [CrossRef] [Scilit]

Disclaimer/Publisher’s Note: The statements, opinions and data contained in all publications are solely those of the individual author(s) and contributor(s) and not of MDPI and/or the editor(s). MDPI and/or the editor(s) disclaim responsibility for any injury to people or property resulting from any ideas, methods, instructions or products referred to in the content. |
© 2025 by the authors. Licensee MDPI, Basel, Switzerland. This article is an open access article distributed under the terms and conditions of the Creative Commons Attribution (CC BY) license (https://creativecommons.org/licenses/by/4.0/).