


Abstract
Ensuring safety in autonomous vehicles (AVs) requires predictive control methods that can handle dynamic constraints, uncertain interactions, and real-time decision making. This review examines safety-oriented model predictive control (MPC) for AVs using a PRISMA-guided screening process. From 363 records published between January 2015 and March 2026, 101 peer-reviewed studies were selected for qualitative synthesis. The literature is organized into three domains: collision avoidance and risk mitigation, trajectory tracking and path following, and intersection and coordination tasks. Across these domains, MPC has evolved from nominal tracking and geometric avoidance toward risk-aware, robust, hierarchical, and learning-enhanced formulations. Unlike broader reviews on autonomous driving control, this review focuses specifically on safety-oriented MPC and compares the reviewed literature in terms of safety mechanisms, uncertainty treatment, validation practice, computational feasibility, and deployment limitations. The review shows that MPC remains one of the most versatile frameworks for AV safety, but the evidence base is weakened by heavy reliance on simulation, inconsistent safety metrics, limited validation under uncertainty, and uneven treatment of computational feasibility. The most promising directions are hybrid architectures that combine model-based safety guarantees with uncertainty-aware prediction, learning-assisted adaptation, and scalable coordination mechanisms.
1. Introduction
Autonomous vehicles (AVs) promise improvements in mobility, efficiency, and safety, but these benefits depend on the ability of the control stack to prevent unsafe motion under uncertainty [1,2,3,4]. Safety in AVs is not limited to lane keeping or path following; it also requires timely reaction to dynamic obstacles, uncertain surrounding agent behavior, limited sensing, actuator constraints, and rapidly changing traffic contexts [5,6,7,8,9,10,11]. Model predictive control (MPC) remains one of the most influential control paradigms for this problem because it optimizes future actions over a receding horizon while explicitly accounting for system dynamics and operational constraints [12,13,14,15,16]. This predictive and constraint-aware structure makes MPC attractive for safety-critical tasks such as collision avoidance, trajectory tracking, lane changing, overtaking, merging, and cooperative maneuvering [4,10,11,17,18,19,20].
The recent AV literature has expanded well beyond classical linear or nonlinear MPC. Current studies increasingly combine MPC with probabilistic risk models, learning-based residual estimators, perception modules, communication layers, and interaction-aware decision models [5,10,11,17,21,22,23,24]. As a result, the field now contains a wide range of formulations that differ not only in controller design but also in how they define, approximate, and validate safety. This methodological diversity has created a fragmented evidence base: some studies emphasize nominal path tracking, others focus on obstacle avoidance or risk-aware planning, while a smaller group addresses cooperative and multi-agent safety under communication and interaction constraints. Existing surveys on autonomous driving and predictive control provide a useful background, but they do not sufficiently isolate safety-oriented MPC as a review object. A focused synthesis is needed to distinguish nominal tracking results from genuine safety contributions; to compare how different studies represent risk and constraints; and to identify where the evidence remains weak, overly simulation-driven, or insufficiently connected to real-time deployment.
Although the broader autonomous driving literature includes surveys on motion planning, control, collision avoidance, and intelligent transportation systems, safety-oriented MPC has often been treated as one component within wider AV control taxonomies rather than as the central object of analysis. This distinction is important because not every MPC-based AV study provides a direct safety contribution: some studies mainly improve nominal tracking accuracy, while others explicitly encode collision avoidance, risk metrics, uncertainty propagation, robust constraints, safety filters, or cooperative conflict resolution.
The novelty of this review is therefore threefold. First, it isolates safety-oriented MPC as the primary review object and separates nominal path following contributions from studies in which safety constraints, risk mitigation, or safe interaction are central to the controller design. Second, it organizes the selected studies according to safety function—collision avoidance and risk mitigation, trajectory tracking and path following under safety constraints and intersection and coordination tasks—rather than only by controller type. Third, it evaluates the evidence base through implementation-relevant dimensions, including safety mechanism, uncertainty treatment, validation level, computational feasibility, scalability, and deployment limitations. This positioning allows the review to move beyond a descriptive collection of studies toward a critical synthesis of how MPC contributes to AV safety and where the evidence remains insufficient for real-world deployment.
To clarify the system-level position of safety-oriented MPC in autonomous driving, Figure 1 illustrates how the MPC layer interacts with perception, prediction, planning, and vehicle actuation. The figure shows that MPC does not operate as an isolated controller; rather, it receives state estimates, reference trajectories, road and lane constraints, predicted surrounding agent information, actuator limits, and safety constraints before generating steering, braking, acceleration, and safe predicted trajectory outputs.
Figure 1.
Position of safety-oriented MPC within the autonomous driving stack.
This paper therefore presents a systematic review of safety-oriented MPC strategies for AVs using a PRISMA-guided selection process. The review covers peer-reviewed studies published between January 2015 and March 2026 and synthesizes 101 included papers across three thematic domains: collision avoidance and risk mitigation, trajectory tracking and path following, and intersection and coordination tasks. The review has four objectives: (i) to classify the main safety-oriented MPC formulations used in AV research; (ii) to compare their assumptions, safety mechanisms, uncertainty treatments, validation settings, and implementation evidence; (iii) to identify recurrent technical limitations, especially those related to computation, uncertainty, scalability, and fragmented system integration; and (iv) to highlight the most credible future research directions for deployable AV safety control. The remainder of the paper is organized as follows. Section 2 describes the review methodology and screening logic. Section 3 presents the thematic synthesis. Section 4 discusses cross-cutting challenges and engineering deployment considerations. Section 5 outlines future research directions. Section 6 concludes the paper.
2. Methodology
This systematic literature review was structured according to the logic of PRISMA 2020 to improve transparency, selection traceability, and synthesis discipline. The review process followed the standard stages of identification, duplicate removal, title/abstract screening, full-text eligibility assessment, and final inclusion. Across the four selected databases, 363 records were identified; 15 duplicates were removed; 348 records were screened; 204 were excluded after title and abstract review; 144 full-text papers were assessed; 43 were excluded at full text; and 101 studies were retained for qualitative synthesis. Figure 2 summarizes the study selection process. Because the included studies differed substantially in vehicle models, scenario definitions, validation settings, uncertainty treatments, and reported metrics, the review was designed as a qualitative evidence synthesis rather than a statistical meta-analysis. In addition to identifying relevant studies, the methodology was designed to support structured comparison across safety mechanisms, MPC variants, uncertainty treatments, validation levels, and implementation-related evidence. To support transparency, reproducibility, and traceability of the selection process and inclusion criteria, this systematic review was registered on the Open Science Framework (OSF) under the same title.
Figure 2.
PRISMA 2020 flow diagram.
2.1. Database Selection and Search Strategy
Four databases were searched because together they provide broad coverage of control, robotics, intelligent transportation, and applied automation research: IEEE Xplore, MDPI, Web of Science, and ScienceDirect. The search window covered January 2015 to March 2026, which captures the period in which safety-oriented MPC for AVs expanded rapidly in both methodological variety and application scope.
The search strategy combined three concept groups: (1) autonomous driving terms (e.g., autonomous vehicle, automated driving, connected autonomous vehicle), (2) predictive control terms (e.g., model predictive control, MPC, nonlinear MPC, robust MPC, stochastic MPC), and (3) safety-oriented task terms (e.g., collision avoidance, risk-aware planning, safe tracking, intersection management, lane change, overtaking, coordination). Database-specific syntax was adapted as needed, but the conceptual scope was kept constant across sources. A representative base query used to guide database adaptation is (“autonomous vehicle” OR “automated driving” OR “connected autonomous vehicle”) AND (“model predictive control” OR MPC OR “nonlinear model predictive control” OR “robust MPC” OR “stochastic MPC”) AND (safety OR “collision avoidance” OR “risk-aware” OR “safe tracking” OR “intersection management” OR “lane change” OR overtaking OR coordination).
To further clarify the composition of the reviewed evidence base, the 101 included studies were also grouped by publication venue or source category after the final selection stage. This classification is distinct from the database search process, since the four searched databases were used to identify candidate records, whereas the distribution below describes the publication sources of the final included studies. IEEE-affiliated journals and conference proceedings represented the largest share of the included literature, with 58 studies, corresponding to approximately 57.4% of the final corpus. MDPI journals contributed 16 studies, or approximately 15.8%, while IFAC-PapersOnLine contributed 11 studies, or approximately 10.9%. Elsevier journals and proceedings, excluding IFAC-PapersOnLine papers counted separately, contributed 10 studies, or approximately 9.9%. The remaining 6 studies, or approximately 5.9%, were published by other sources. This distribution indicates that the reviewed literature is mainly concentrated in control, intelligent transportation, vehicle systems, and automation-oriented publication venues, which is consistent with the technical focus of safety-oriented MPC for autonomous vehicles.
2.2. Screening, Eligibility, and Data Extraction
Screening was performed in staged form. After duplicate removal, titles and abstracts were checked against predefined relevance criteria. Potentially eligible papers then underwent full-text assessment. The purpose of this staged process was to exclude papers that used MPC in autonomous driving contexts without making safety a primary control objective, while retaining studies in which safety constraints, collision mitigation, safe motion planning, or coordination under risk formed part of the core contribution.
To reduce subjective selection bias, each paper was assessed according to the same eligibility logic: the study had to include an identifiable MPC formulation, an autonomous or connected driving application, and a safety-related control objective. During full-text assessment, particular attention was given to whether safety was treated as a central design element rather than as a secondary performance outcome.
2.2.1. Inclusion Criteria
A study was retained when it satisfied all of the following conditions: it proposed or applied MPC or a clearly defined MPC variant; the application domain was autonomous or connected autonomous driving; the control problem was explicitly safety-related; the paper was peer-reviewed; and the publication fell within the selected time window.
2.2.2. Exclusion Criteria and Final Selection
Studies were excluded when safety was peripheral rather than central, when MPC was applied outside the AV domain, when the work was non-peer-reviewed, or when the full text did not support inclusion after detailed inspection. Common reasons for full-text exclusion were weak thematic fit, absence of a genuine safety objective, or use of predictive control in contexts unrelated to autonomous driving.
For each included study, information was extracted on MPC variant, application scenario, safety mechanism, uncertainty treatment, validation setting, and stated limitations. Additional implementation-related information was also extracted when available, including reported computation time, solver type, prediction horizon, sampling time, hardware or simulation platform, and evidence of real-time feasibility. During synthesis, the studies were compared along dimensions that matter directly for scientific credibility: controller structure, safety representation, interaction modeling, reported real-time feasibility, and level of validation, including simulation, software-in-the-loop, hardware-in-the-loop, or experimental testing. These extracted fields were then used to support the thematic classification and the cross-domain critical comparison presented later in the review.
2.3. Thematic Classification and Comparative Synthesis
To synthesize the literature in a structured manner, the included studies were classified into one or more of three domains according to the primary safety function addressed by MPC: collision avoidance and risk mitigation; trajectory tracking and path following under safety constraints; and intersection/coordination tasks involving multi-agent or interactive traffic scenarios. Table 1 summarizes the thematic coverage of the included studies across these three safety-oriented MPC application domains.
Table 1.
Thematic coverage of included studies across safety-oriented MPC application domains.
This thematic organization was used for comparison rather than as a claim that the three categories are fully disjointed. Several papers span multiple functions, especially those combining tracking with obstacle avoidance or coordination with risk-aware planning. In such cases, studies were discussed in the domain most closely aligned with their principal safety contribution. The classification was also used to support cross-domain comparison of MPC variants, safety mechanisms, uncertainty treatment, validation practice, computational feasibility, and implementation limitations. This comparative structure was adopted to avoid presenting the literature only as a descriptive list of studies and to highlight recurring trade-offs between safety guarantees, real-time feasibility, scalability, and deployment readiness.
3. Thematic Synthesis of the Literature
This section synthesizes the included studies by emphasizing cross-study patterns rather than sequential descriptions of individual papers. The focus is on how each class of MPC formulation contributes to safety, how safety is represented, what assumptions are imposed, and how convincingly the claims are validated. The equations and algorithmic patterns are retained only as compact representative abstractions; they are used to support comparison across MPC variants rather than to provide a tutorial derivation of each method.
To keep the synthesis comparative, the reviewed formulations are grouped by their dominant safety mechanism: nominal and constraint-based MPC, robust and stochastic MPC, learning-enhanced MPC, and cooperative or hierarchical MPC. Nominal and constraint-based MPC mainly provide reference tracking and explicit road, obstacle, and actuator constraints; robust and stochastic MPC address bounded or probabilistic uncertainty; learning-enhanced MPC improves prediction or model adaptation; and cooperative or hierarchical MPC extends safety reasoning to interacting agents and layered decision making. This grouping is used to interpret the studies by safety role rather than by isolated mathematical form.
Figure 3 presents a generic safety-oriented MPC architecture that summarizes the recurring components found across the reviewed studies, including input information, prediction, cost design, safety constraints, uncertainty handling, optimization, and fallback safety mechanisms.
Figure 3.
Generic architecture of safety-oriented MPC for autonomous vehicles.
Figure 4 maps the main MPC variants to their dominant safety mechanisms and provides a taxonomy for interpreting the formulations reviewed in the following subsections.
Figure 4.
Taxonomy of safety-oriented MPC variants and dominant safety mechanisms.
3.1. Collision Avoidance and Risk Mitigation
Collision avoidance is one of the most fundamental safety requirements in autonomous driving. MPC is widely used for this purpose because it predicts future vehicle states while enforcing obstacle, stability, and actuation constraints within a unified optimization framework. In the reviewed literature, collision-avoidance MPC can be grouped into three main directions: constraint-based and reactive methods, uncertainty-aware and risk-aware control, and perception-aware or learning-augmented safety architectures. Across these groups, the main cross-study trend is a shift from simple geometric obstacle avoidance toward probabilistic, interaction-aware, and dynamically feasible safety planning. Therefore, the following synthesis evaluates collision-avoidance MPC not only by whether it produces collision-free trajectories but also by how it encodes safety, handles uncertainty, preserves real-time feasibility, and supports deployment in dynamic traffic environments.
To provide a common analytical frame, Equations (1)–(4) summarize the recurring structure of collision-avoidance MPC: vehicle prediction, reference tracking, obstacle-related safety terms, state/input constraints, and receding-horizon re-optimization. They are included as a compact comparative template rather than as a tutorial derivation or a single formulation shared by all reviewed studies. In practice, the optimization is re-solved at each control update using refreshed state estimates and obstacle predictions.
where is the system state vector at step , while is the control input vector; and are the global position; is the yaw/heading angle; is the longitudinal speed; is the longitudinal acceleration command; and is the steering command. Here, is the objective function over the prediction horizon ; is the reference state or trajectory at step ; and are weighting matrices for tracking error and control effort, respectively, where is a positive semi-definite weighting matrix; and is a positive definite weighting matrix. The initial selection of these weighting matrices can be carried out using Bryson’s rule; is the weight assigned to obstacle ; is the obstacle-related penalty function, used to increase the cost as the ego vehicle approaches an obstacle, thereby encouraging obstacle clearance in the optimized trajectory; is the distance to obstacle at step ; and is the number of obstacles considered.
Algorithm 1 summarizes this pattern, which is common across the reviewed collision-avoidance MPC implementations.
| Algorithm 1: Receding-horizon execution of collision-avoidance MPC | |
| Inputs: estimation of current state ; reference ; predictions of obstacle ; horizon . Output: applied control . | |
| |
3.1.1. Constraint-Based and Reactive Collision Avoidance
Constraint-based and reactive collision-avoidance MPC primarily encodes safety through geometric clearance, lane or road boundaries, and actuator-feasible evasive behavior. Across the reviewed studies, APF/sigmoid barriers, hard safety constraints, NMPC escape maneuvers, and integrated steering–braking or yaw control strategies serve the same core purpose: keeping the predicted trajectory outside unsafe regions while preserving vehicle feasibility [11,12,13,14,20,25,26,28,58,67,68,79,86,96,97,98]. The main strength of this group is implementation simplicity and clear geometric interpretability; the main limitation is that clearance-based safety remains sensitive to perception error, obstacle intent uncertainty, and rapidly changing maneuver space.
More structured path-generation mechanisms, including time-scaled collision-cone MPC, CQP-based MPC, safety-tunnel MPC, and hybrid MPC–spline lane-change control, improve path smoothness and reduce local-minimum effects [69,70,83,93]. Therefore, the cross-study trend is a shift from reactive obstacle repulsion toward corridor- or maneuver-structured collision avoidance, where timing, road curvature, and dynamic feasibility become as important as obstacle distance.
Equations (5)–(11) group the main distance-based safety encodings used in constraint-based collision-avoidance MPC, including geometric clearance, hard and soft distance constraints, slack penalties, repulsive potentials, sigmoid shaping, and speed-dependent safety margins.
where is the predicted position of obstacle at step .
To guarantee collision avoidance, a hard safety constraint is imposed by requiring the distance between the ego vehicle and each obstacle to remain above a prescribed minimum clearance, expressed as:
where represents the required minimum safety distance, which may be constant or time-varying.
To improve feasibility in constrained or highly dynamic scenarios, the hard clearance constraint can be relaxed by introducing a non-negative slack variable . This results in the following soft-constraint formulation:
where larger values of correspond to greater violations of the clearance requirement and are used to maintain feasibility when strict satisfaction of the hard constraint is not possible.
Violations of the soft distance constraint are penalized in the objective function through an additional slack penalty term defined as:
where is a tuning coefficient that regulates the severity of constraint violation penalties, and denotes the number of obstacles considered.
In reactive collision-avoidance formulations, the hard or soft clearance constraints are often complemented by smooth repulsive potentials to encourage early avoidance behavior. A commonly used artificial potential field penalty is defined as:
where controls the repulsion strength, denotes the obstacle distance, and is the influence distance beyond which the repulsive effect is disabled.
To ensure smooth safety shaping near the minimum clearance boundary, a sigmoid-based mapping can be employed, which is given by:
where determines the steepness of the transition, and denotes the minimum clearance threshold.
In medium- and high-speed driving scenarios, the minimum clearance is often modeled as a time-varying quantity to reflect speed-dependent risk, leading to:
where is the base clearance, is a time-headway parameter, and denotes the relative speed magnitude at step .
Algorithm 2 summarizes how these distance constraints and shaping terms are assembled within the receding-horizon loop for constraint-based and reactive collision avoidance.
| Algorithm 2: Constraint-based/reactive MPC assembly for obstacle avoidance | |
| Inputs: , , , design parameters . Output: applied control . | |
| |
3.1.2. Risk-Aware and Robust Control Under Uncertainty
Risk-aware and robust MPC extends collision avoidance from deterministic clearance to safety under uncertain obstacle behavior, perception, control inputs, and vehicle dynamics. Across the reviewed studies, Monte Carlo risk estimation, chance constraints, robust/tube-based formulations, reachability analysis, and adaptive updates serve a common purpose: preserving feasible safety margins when future motion or model behavior is uncertain [6,9,10,11,27,59,85,94]. Compared with purely geometric methods, these approaches provide stronger uncertainty-aware safety interpretations, but their credibility depends on the realism of the assumed probability models, disturbance bounds, or reachable sets.
A cross-study trend is the use of risk-shaped decision making rather than distance-only avoidance. Collision probability, time-to-collision, overtaking risk, and uncertainty-calibrated margins allow controllers to distinguish situations with similar geometry but different hazard levels [85,94]. This is particularly relevant in overtaking and emergency lane-change scenarios, where the controller must decide not only how to maneuver but also whether the maneuver should be attempted.
The practical limitation is computational and modeling burden. Robust and stochastic safety mechanisms can improve confidence under uncertainty, but they may become conservative or difficult to solve online, especially in high-speed, mixed-traffic, or rapidly changing scenarios. Therefore, their deployment value depends on whether uncertainty assumptions are valid and whether optimization remains feasible within real-time driving constraints.
Equations (12)–(15) summarize the two main uncertainty-handling patterns in the reviewed collision-avoidance literature: probabilistic safety through chance constraints and Monte Carlo risk estimation and robust safety through bounded disturbances and invariant safe sets.
where denotes probability, is the uncertain distance to obstacle at step , is the required clearance, and represents the allowable risk level.
In practice, this probabilistic constraint is commonly approximated using Monte Carlo sampling of obstacle predictions. The resulting empirical collision probability estimate is computed as:
where is the estimated probability of violating the clearance constraint for obstacle at step , is the number of Monte Carlo samples, and the indicator function counts the proportion of samples for which the clearance condition is violated.
Robust MPC formulations instead model uncertainty as an additive bounded disturbance acting on the system dynamics, leading to:
where represents an unknown disturbance and denotes a bounded uncertainty set.
To guarantee safety under all admissible disturbances, reachability-based and invariant set approaches enforce that the predicted state remains within a predefined safe set throughout the horizon, expressed as:
where denotes the set of states that satisfy safety requirements such as collision avoidance and vehicle stability.
Algorithm 3 summarizes the sampling-based risk evaluation step used to convert uncertain obstacle predictions into collision risk constraints for the MPC solver.
| Algorithm 3: Monte Carlo risk evaluation for chance-constrained MPC | |
| Inputs: predicted obstacle distribution/model; horizon ; number of samples ; clearance threshold ; risk bound . Output: estimated collision risk constraint values . | |
| |
3.1.3. Perception-Aware and Learning-Augmented Safety Architectures
Perception-aware and learning-augmented MPC architectures extend collision avoidance by connecting the controller with prediction, learning, communication, or supervisory safety layers. Across the reviewed studies, pedestrian forecasting, game-theoretic interaction modeling, Gaussian Process residual learning, dual-layer safety control, and event-triggered coordination all serve the same broader purpose: improving anticipation while retaining explicit safety constraints or fallback mechanisms [5,10,24,42,82].
The main cross-study trend is that collision avoidance is increasingly treated as an interaction-aware safety problem rather than a single-vehicle obstacle bypass task. In mixed traffic, surrounding vehicles and pedestrians are active agents whose future motion can affect whether an evasive maneuver remains feasible. Therefore, cooperative crash-avoidance, lane-change decision models, graph-search-assisted planners, and Stackelberg-game formulations improve safety mainly by representing maneuver dependency, relative intent, and conflict resolution [17,19,84,86,98,99].
The main limitation is safety assurance. Learning and perception modules can improve model accuracy and anticipation, but they can also introduce prediction error, distribution shift, and communication delay into the MPC constraints. For this reason, the strongest architectures use learning to support prediction or adaptation while retaining explicit safety envelopes, uncertainty-aware tightening, or fallback filters inside the MPC framework.
Equations (16)–(20) group the main mechanisms used in perception-aware and learning-augmented MPC: forecast-based obstacle prediction, learned residual dynamics, uncertainty-aware constraint tightening, safety-filter correction, and event-triggered information exchange.
where denotes the prediction model associated with obstacle , and represents the corresponding prediction uncertainty, for example in the form of a covariance matrix.
Learning-augmented MPC schemes often enhance the nominal prediction model by incorporating a data-driven correction term to compensate for unmodelled dynamics. A common formulation based on Gaussian Processes augments the nominal dynamics as:
where is the physics-based nominal model and denotes the GP mean function capturing residual modeling errors.
To account for uncertainty in the learned model and maintain safety guarantees, the minimum clearance constraint can be tightened using the GP predictive uncertainty, leading to:
where is a measure of GP uncertainty, is a confidence scaling factor, and is the baseline minimum clearance.
Dual-layer safety architectures introduce a safety filter that minimally modifies the nominal control input while enforcing safety constraints. This safety-filtered input is obtained by solving:
where is the nominal control input produced by the primary MPC, is a safety constraint function, is the admissible input set, and denotes the Euclidean norm.
In cooperative or decentralized settings, communication between agents is often regulated using an event-triggered mechanism to reduce bandwidth usage. A transmission event is triggered whenever the deviation signal exceeds a predefined threshold, which can be expressed as:
where denotes the triggering error signal, such as the deviation since the last transmission, and is the event-triggering threshold.
Algorithm 4 summarizes how a safety-filter layer can act as a fallback mechanism when the nominal MPC prediction approaches a safety violation.
| Algorithm 4: Safety-filter integration for dual-layer MPC | |
| Inputs: nominal MPC input ; current state ; admissible input set ; safety function . Output: applied control . | |
| |
Together, Equations (5)–(20) and Algorithms 1–4 map the reviewed collision-avoidance literature into three implementable MPC patterns: distance-based constraint encoding, uncertainty-aware risk or robustness treatment, and perception/learning integration with safety backstops. Table 2a–c summarize these patterns by technique and control objective. Overall, the main trade-off is between simplicity and uncertainty handling: geometric and reactive methods are easier to implement, while robust, risk-aware, perception-enhanced, and learning-supported methods improve anticipation and resilience but increase computational burden and safety assurance requirements.
Table 2.
(a). Summary of constraint-based and reactive MPC techniques for collision avoidance and risk mitigation. (b). Summary of risk-aware and robust MPC techniques for collision avoidance and risk mitigation. (c). Summary of perception-enhanced and interaction-aware MPC architectures for collision avoidance and risk mitigation.
3.2. Trajectory Tracking and Path Following
Trajectory tracking is a core AV control function because the vehicle must follow a planned path while satisfying dynamic, physical, comfort, and safety constraints. Across the reviewed studies, tracking-oriented MPC can be grouped into three main directions: nominal and adaptive tracking, robust and learning-enhanced tracking under uncertainty, and comfort- or context-aware formulations. The cross-study trend is that path following has evolved from nominal reference tracking into a broader safety-oriented motion control problem, where lateral accuracy, longitudinal regulation, obstacle accommodation, actuator feasibility, road curvature, tire adhesion limits, and real-time implementation are increasingly treated together rather than as isolated objectives [1,7,8,10,22,24,31,42,43,44,45,46,47,49,51,71,74,90]. Therefore, the following synthesis evaluates tracking MPC not only by tracking error but also by robustness, comfort, actuator feasibility, and deployment relevance.
Equations (21)–(24) summarize the common tracking MPC template used to compare the reviewed studies: tracking error definition, vehicle prediction, finite-horizon tracking cost, and state/input constraints.
where is the current or predicted system state and is the desired reference state at the same step.
The system dynamics used for prediction over the horizon are given by:
where denotes the possibly nonlinear vehicle model employed by the MPC controller.
Based on the tracking error definition, the finite-horizon tracking objective is formulated to penalize both state deviation and control effort, resulting in the cost function:
where is the tracking cost over the prediction horizon , and are positive semi-definite weighting matrices that penalize tracking error and control effort, respectively, and P is the terminal weighting matrix applied to the final tracking error.
The optimization problem is subject to state and input constraints enforced at each step of the prediction horizon, expressed as:
where and are the admissible sets for the state and input, respectively.
3.2.1. Nominal and Adaptive MPC for Tracking
Nominal and adaptive tracking MPC provides the baseline structure for path following under vehicle and input constraints. Across the reviewed studies, linear, nonlinear, adaptive, and hybrid MPC formulations are used to improve tracking accuracy, update model parameters, switch operating modes, or maintain performance under changing driving conditions [7,43,44,45,46,48,58]. Their main strength is practical suitability for structured road following tasks and real-time implementation; their main limitation is that safety depends strongly on whether model updates, mode switching, and constraint handling remain reliable under disturbances, perception uncertainty, and rapidly changing road conditions.
Recent studies extend this baseline in three directions: adaptive prediction horizons for curvature-dependent tracking, hierarchical or integrated planning-and-control structures, and specialized motion control designs for tire adhesion limits, drifting, steering torque actuation, and four-wheel-independent steering/driving [33,34,35,38,39,40,71,72,87,100]. The cross-study trend is that nominal and adaptive tracking MPC is no longer limited to lateral error correction; it increasingly shapes dynamically feasible and context-aware motion according to road geometry, vehicle architecture, and operating speed.
Equations (25)–(27) group the main prediction structures used in nominal, adaptive, and hybrid tracking MPC: linearized vehicle prediction, online parameter adaptation, and mode-dependent dynamics.
where and are the possibly time-varying system matrices obtained from linearization, is an affine offset term accounting for higher-order dynamics, and and denote the state and control input, respectively.
To address changes in vehicle dynamics and environmental conditions, adaptive MPC formulations explicitly update model parameters online. A compact representation of such an adaptive model is given by:
where is the vector of estimated or adapted model parameters at step , denotes the parameter-update increment obtained from online identification, and represents the parameterized prediction model.
Hybrid MPC approaches further extend adaptive schemes by allowing the controller to switch between multiple candidate models or control modes. This behavior can be expressed by introducing a discrete mode variable, leading to:
where denotes the active mode at step , is the finite set of admissible modes, and is the dynamics model associated with the selected mode.
Algorithms 5 and 6 summarize how these prediction structures are used in nominal, adaptive, and hybrid tracking MPC loops.
| Algorithm 5: Nominal tracking MPC (linear/linearized MPC execution) | |
| |
| Algorithm 6: Adaptive/hybrid tracking MPC (parameter/mode update + MPC solve) | |
| |
3.2.2. Robust and Learning-Enhanced Tracking Under Uncertainty
Robust and learning-enhanced tracking MPC addresses model mismatch, external disturbances, parameter drift, and uncertain operating conditions. Across the reviewed studies, LPV/tube-based robust MPC, Gaussian Process residual modeling, tuning-parameter-free MPC, and two-layer learning-supported MPC all aim to preserve constraint satisfaction and tracking reliability when the nominal vehicle model is incomplete or changing [15,16,21,24,51,52]. Compared with nominal and adaptive tracking MPC, these formulations provide stronger protection against uncertainty, but they require credible uncertainty bounds, interpretable learned corrections, and evidence of real-time solvability.
Recent studies broaden robust tracking beyond disturbance rejection alone. Tire-adhesion-aware NMPC, curvature-dependent horizon adaptation, integrated spatial kinematics–dynamics MPC, and four-wheel-independent steering/driving control show that robustness increasingly depends on preserving stability when road friction, curvature, actuator effectiveness, or available control authority change [31,32,33,38,39]. In this sense, robust tracking is becoming a coordinated management problem involving lateral motion, longitudinal regulation, actuator allocation, and stability-related constraints.
The main cross-study lesson is that learning is most useful when it refines model-based prediction rather than replacing it. Residual correction, online parameter updates, and horizon adjustment rules can improve tracking under uncertainty, but the safety value of these methods depends on whether the learned component remains bounded, interpretable, and compatible with explicit MPC constraints.
Equations (28)–(32) summarize the main uncertainty representations used in robust and learning-enhanced tracking MPC: bounded additive disturbances, nominal/error decomposition, tightened admissible sets, learned residual dynamics, and GP-based uncertainty tightening.
where is an unknown but bounded disturbance and is the associated uncertainty set.
A common robust decomposition separates the predicted state into a nominal component and an error component:
where is the nominal state and is a robust error tube or invariant error set.
To preserve constraint satisfaction under bounded uncertainty, tightened admissible sets are often enforced on the nominal prediction:
where denotes the Pontryagin difference and is a feedback gain used to keep the actual trajectory within the robust tube.
Learning-enhanced MPC schemes often augment the nominal model with a data-driven residual term. A common GP-based representation is:
where is the nominal prediction model and denotes the learned mean correction term.
To account for uncertainty in the learned residual model, tracking constraints can be tightened using the predictive variance:
where represents the GP uncertainty bound at step and is a confidence-scaling coefficient.
Algorithms 7 and 8 summarize how robust and learning-enhanced tracking MPC implements these uncertainty-handling mechanisms within the receding-horizon loop.
| Algorithm 7: Robust tracking MPC (LPV/tube-based execution) | |
| |
| Algorithm 8: Learning-enhanced tracking MPC (residual learning + MPC solve) | |
| |
3.2.3. Comfort- and Context-Aware Formulations
Comfort- and context-aware tracking MPC extends conventional path following by including ride quality, steering smoothness, lateral acceleration, speed adaptation, and scenario-dependent tuning within the control objective. Across the reviewed studies, these formulations show that tracking accuracy alone is not sufficient for safe and acceptable AV behavior when the resulting motion is uncomfortable, unstable, or overly aggressive [2,34,36,40,47,61,100].
The main cross-study trend is the integration of comfort and context into the predictive control loop rather than treating them as secondary add-ons. Cost-function adaptation, curvature-aware prediction, fuzzy context switching, infrastructure-supported planning, and steering-actuation-aware control allow the controller to balance tracking accuracy, stability, comfort, and feasibility under changing road and traffic conditions.
A further trend is the coupling of lateral path tracking with longitudinal velocity or spacing regulation. Integrated path-and-velocity control and energy- or context-aware designs indicate that safer and smoother motion often requires proactive speed adaptation, especially during curvature transitions, vehicle following, or obstacle-constrained tracking [39,61,88,100].
Equations (33)–(38) summarize the main comfort- and context-aware extensions used in tracking MPC: comfort-augmented cost terms, input rate penalties, lateral acceleration approximation, context-dependent weighting, prediction horizon adaptation, and longitudinal spacing control.
where , , and are non-negative weights assigned to input smoothness, yaw rate moderation, and lateral acceleration moderation, respectively.
The input rate term is defined as:
which is commonly used to reduce jerky steering or acceleration changes.
A practical approximation of lateral acceleration used in path following formulations is:
where is the longitudinal speed and is the yaw rate.
Context-aware MPC can be represented by introducing a context or scheduling variable that modulates either the cost or the model:
where is the admissible context set and the coefficients and determine the relative importance of comfort- and context-dependent objectives.
When prediction horizon adaptation is used, the prediction length may be adjusted as a function of speed, curvature, or operating condition:
where is the active prediction horizon and is the road curvature at step .
In vehicle-following and platooning scenarios, longitudinal safety and tracking objectives are often enforced using a time headway spacing policy. The desired inter-vehicle spacing and the corresponding spacing error are defined as:
where is the actual longitudinal spacing, is the desired spacing, is the standstill distance, is the time headway parameter, and denotes the vehicle speed.
Algorithms 9 and 10 summarize how comfort penalties and context-dependent adaptation are incorporated into the tracking MPC loop.
| Algorithm 9: Comfort-aware tracking MPC (objective augmentation) | |
| |
| Algorithm 10: Context-aware tracking MPC (context evaluation and horizon adaptation) | |
| |
Table 3a–c summarize the reviewed tracking-oriented MPC studies by technique and control objective. The main cross-study trade-off is between nominal tracking performance, robustness, comfort, and implementation complexity: nominal and adaptive MPC remains suitable for structured real-time tracking, robust and learning-enhanced MPC improves uncertainty handling at higher computational and modeling cost, and comfort- or context-aware MPC improves motion acceptability but still requires stronger integration with safety metrics.
Table 3.
(a). Summary of nominal and adaptive MPC techniques for trajectory tracking and path following. (b). Summary of robust and learning-enhanced MPC techniques for trajectory tracking and path following. (c). Summary of comfort and context-aware MPC techniques for trajectory tracking and path following.
Collectively, the embedded formulations in Equations (21)–(38) and Algorithms 5–10 map the reviewed tracking literature into implementable MPC components: nominal and adaptive prediction with horizon optimization (Section 3.2.1), robust and learning-enhanced uncertainty handling through tightening and residual modeling (Section 3.2.2), and comfort- and context-aware extensions through smoothness penalties, adaptive weighting, and integrated longitudinal–lateral objectives (Section 3.2.3).
3.3. Intersection and Coordination Tasks
Autonomous vehicle coordination at intersections, lane merges, roundabouts, and cooperative maneuvers creates challenges beyond single-vehicle control because safety depends on interaction timing, shared constraints, communication quality, and surrounding agent behavior. Across the reviewed studies, coordination-oriented MPC can be grouped into cooperative and predictive maneuvering, hierarchical and contract-based architectures, and centralized or mission-level planning. The cross-study trend is that coordination MPC has moved beyond simple trajectory exchange toward interaction prediction, merge gap evaluation, risk-sensitive negotiation, and shared longitudinal–lateral motion planning. Therefore, this domain is evaluated not only by conflict-free trajectory generation but also by scalability, communication assumptions, computational feasibility, and robustness to heterogeneous human-driven behavior.
Equations (39)–(41) summarize the common cooperative MPC structure used to compare coordination studies: individual vehicle dynamics, shared interaction costs, and agent-specific state/input constraints.
where and denote the state and control input of vehicle at step , respectively, and represents the corresponding vehicle dynamics model.
Coordination among multiple vehicles is achieved by coupling individual objectives through shared cost terms or interaction penalties, resulting in a cooperative MPC optimization problem of the form:
where is the number of vehicles, is the reference trajectory for vehicle , and are weighting matrices, denotes the set of interacting vehicle pairs, and represents interaction or safety coupling terms such as collision avoidance or precedence enforcement.
Cooperative optimization is subject to individual state and input constraints for each vehicle over the prediction horizon, expressed as:
where and denote the admissible state and input sets associated with vehicle .
3.3.1. Cooperative and Predictive Maneuvering
Cooperative and predictive maneuvering MPC extends safety reasoning from the ego vehicle to interacting with traffic participants. Across the reviewed studies, cooperative trajectory exchange, event-triggered communication, game-theoretic prediction, reachability analysis, and nonlinear cooperative MPC are used to coordinate merging, overtaking, intersection negotiation, turning, and roundabout maneuvers [3,4,8,10,11,73,76,77,82]. The main safety contribution is anticipatory coordination: the controller plans not only around static constraints but also around expected interaction windows and feasible responses of nearby agents.
A key cross-study trend is the shift from pure trajectory sharing toward structured interaction modeling. Distributed cooperative path planning, human driver trajectory integration, merge gap management, connected platoon coordination, and intersection speed planning show that safe maneuvering often depends on predicting whether surrounding vehicles will create, preserve, or close feasible gaps [20,75,76,91,92]. This is especially important in mixed traffic, where the ego vehicle’s safe action depends on both its own feasibility and the probable evolution of neighboring agents.
The main deployment limitation is dependence on communication quality, prediction accuracy, and solver update speed. Cooperative MPC can improve safety and traffic efficiency, but its reliability decreases when shared intent is delayed, surrounding vehicles behave unexpectedly, or the local optimization cannot update fast enough for changing interaction conditions.
Equations (42)–(46) group the main interaction safety mechanisms used in cooperative and predictive MPC: inter-vehicle separation, merge gap constraints, event-triggered communication, best-response interaction modeling, and reachability-based coordination. For inter-vehicle separation, the distance , computed from the planar positions and , is required to remain above a minimum allowable separation , i.e.,
where is the distance between vehicles and at step , is the position of vehicle , and is the minimum allowable separation.
In coordinated merging and lane-change settings, coupling between agents can also be represented through relative gap constraints, where the available gap must satisfy a required target gap , i.e.,
where denotes the available longitudinal or spatiotemporal gap between interacting vehicles and is the required safe gap, which may vary with speed, context, or priority.
To reduce communication burden in decentralized implementations, event-triggered coordination strategies transmit updated information only when the deviation from the last communicated state exceeds a threshold. A standard event-triggering rule can be written as:
where denotes the most recent communication instant for vehicle , and is the triggering threshold.
In game-theoretic or interaction-aware MPC, each vehicle’s decision depends on the predicted behavior of surrounding agents. A generic best-response formulation can be expressed as:
where is the objective of vehicle and denotes the predicted actions of the other agents.
Reachability-based coordination methods often enforce that the future joint state remains inside a safe multi-agent set, expressed as:
where denotes a safe coordination set that excludes collision, precedence violation, or infeasible merge or intersection configurations.
Algorithms 11 and 12 summarize how cooperative MPC combines trajectory or intent exchange with event-triggered communication during decentralized coordination.
| Algorithm 11: Decentralized cooperative MPC with trajectory/intent exchange | |
| |
| Algorithm 12: Event-triggered coordination layer for cooperative MPC | |
| |
3.3.2. Hierarchical and Contract-Based Control Architectures
Hierarchical and contract-based MPC architectures address coordination complexity by separating strategic decisions from low-level dynamically feasible control. Across the reviewed studies, high-level scheduling, contract negotiation, GP-supported dynamic constraints, and lower-level MPC tracking are used to manage intersections, roundabouts, merging, and mixed-traffic coordination while preserving interpretability and feasibility [8,20,24,63,65,73,77,91].
The main cross-study trend is tighter integration between planning, scheduling, speed regulation, and local MPC tracking. Instead of treating coordination as a separate planning problem, recent hierarchical approaches use upper layers to define right-of-way, merging order, passage windows, or feasible constraint sets, while lower layers generate steering and acceleration commands that satisfy vehicle dynamics and safety constraints.
The main limitation is consistency between layers. Safety depends on whether high-level schedules, negotiated contracts, predicted human driver behavior, and low-level feasibility constraints remain mutually compatible under changing traffic conditions, communication delays, and mixed-autonomy behavior.
Equations (47)–(50) group the main hierarchical and contract-based coordination mechanisms used in the reviewed studies: high-level scheduling, schedule-constrained low-level MPC, contract set definition, and contract-constrained feasibility enforcement.
where denotes the set of admissible schedules and is a scheduling objective that may capture delay, conflict reduction, or throughput.
Given the selected schedule, the low-level controller solves a constrained MPC problem that respects the schedule-induced feasible set :
where is the admissible state set induced by the selected coordination or scheduling decision.
Contract-based hierarchical MPC further improves modularity by negotiating admissible constraint sets between layers. This negotiation can be expressed by defining a contract set as:
where denotes the agreed specification between modules, defining required conditions on states and/or inputs.
The controller then enforces feasibility by solving the MPC problem under both the baseline constraints and the negotiated contract constraints, written as:
where optimization enforces both the baseline sets and the contract set across the horizon.
Algorithms 13 and 14 summarize how hierarchical MPC links high-level scheduling or contract negotiation with low-level feasibility checking and control execution.
| Algorithm 13: Hierarchical MPC for intersection coordination | |
| |
| Algorithm 14: Contract-based hierarchical MPC (negotiation + control) | |
| |
3.3.3. Centralized and Mission-Level Planning
Centralized and mission-level MPC coordinates multiple AVs through shared optimization, global state information, or upper-level maneuver reasoning. Across the reviewed studies, these approaches are most useful in structured or infrastructure-supported scenarios such as area coverage, roundabouts, overtaking, merge coordination, and unsignalized intersections, where safe motion depends on passage timing, conflict ordering, right-of-way usage, and interaction with multiple surrounding vehicles [8,20,64,73,74,95,101].
The main cross-study strength of centralized planning is its ability to optimize conflict-zone timing and multi-vehicle behavior explicitly. This can improve global consistency and reduce collision risk in structured traffic layouts. However, the same feature creates the main limitation: centralized MPC becomes less practical as the number of vehicles, communication load, and uncertainty in agent behavior increase.
Mission-level planning is therefore most valuable when it shapes the feasible interaction strategy that lower-level controllers will track, for example, by evaluating whether overtaking is admissible, when a vehicle should enter a roundabout, or how an unsignalized intersection should be crossed. Its practical value depends on whether the upper-level plan remains compatible with real-time local control under limited visibility, uncertain intent, and changing traffic conditions.
Equations (51) and (52) summarize the centralized mission-level MPC pattern used in the reviewed studies: aggregated multi-agent state prediction and joint optimization of tracking and control effort under shared coordination constraints.
where is the aggregated global state, is the aggregated global input, and is the global transition function describing the coupled multi-agent dynamics.
The corresponding centralized optimization is then posed by minimizing a quadratic tracking-and-effort objective over the horizon, expressed as:
where denotes the joint input sequence, is the reference aggregated trajectory, and and are weighting matrices defining the tracking and control effort penalties, respectively.
Algorithm 15 summarizes how centralized MPC performs global optimization and distributes the first-step control actions to participating vehicles.
| Algorithm 15: Centralized multi-agent MPC (global optimization) | |
| |
Table 4a–c summarize the coordination-oriented MPC studies by technique and control objective. The main cross-study trade-off is between global optimality, modularity, and deployability: centralized MPC can improve global consistency but scales poorly with agent number and communication load; distributed and cooperative MPC improves scalability but depends on reliable intent exchange and prediction; and hierarchical or contract-based MPC improves modularity but requires consistency between planning and control layers.
Table 4.
(a). Summary of cooperative and predictive maneuvering MPC techniques for intersection and coordination tasks. (b). Summary of hierarchical and contract-based MPC techniques for intersection and coordination tasks. (c). Summary of centralized and mission-level planning MPC techniques for intersection and coordination tasks.
4. Cross-Cutting Challenges
The reviewed literature confirms that MPC is a powerful framework for AV safety, but it also exposes several recurring weaknesses that limit confidence in deployability. These weaknesses are not isolated to one subfield; they appear across collision avoidance, tracking, and coordination studies. They are particularly important for safety-oriented MPC because a formulation that is mathematically safe may still be difficult to deploy if it cannot handle perception uncertainty, solver delays, communication limits, or actuator constraints within the required real-time control cycle.
The first challenge is computational credibility. Many papers propose richer nonlinear, stochastic, or multi-agent formulations without providing enough evidence that the resulting optimization problems can be solved reliably within the time budgets required by safety-critical driving. Solver choice, horizon length, warm-start strategy, and worst-case execution time are often underreported. This makes it difficult to judge whether the reported safety benefits would persist under realistic sampling times, embedded hardware limitations, emergency maneuvers, or sudden changes in obstacle behavior.
The second challenge is uncertainty treatment. A large share of the literature acknowledges uncertainty in perception, prediction, tire–road interaction, or surrounding agent intent, but fewer papers show how uncertainty propagates through the controller in a way that preserves interpretable safety guarantees. In many cases, robustness is asserted more strongly than it is demonstrated. This gap is especially important in mixed traffic, where safety depends not only on the ego vehicle model but also on uncertain pedestrian behavior, human driver intent, occlusion, sensor noise, and rapidly changing road friction.
The third challenge is fragmented architecture. Perception, prediction, planning, communication, and low-level control are still frequently studied as loosely connected modules. This separation is convenient for analysis, but it weakens claims of end-to-end safety because errors originating upstream are often simplified away before reaching the MPC formulation. For deployable AV systems, safety analysis should therefore account for how perception errors, delayed predictions, map uncertainty, and actuator limitations influence the feasibility and reliability of the MPC solution.
The fourth challenge is scalability in interactive traffic. Cooperative and distributed MPC methods are promising, yet their performance can degrade quickly as the number of agents, communication delays, or behavioral uncertainties increase. Several coordination papers remain convincing only in small or highly structured scenarios. This limitation is particularly relevant for intersections, merges, roundabouts, and dense urban traffic, where safety depends on multiple interacting agents and where centralized or fully cooperative assumptions may not hold.
These challenges can be summarized through four recurrent system-level limitations:
- Scalability of optimization: strongly coupled formulations become difficult to solve or certify as scenario complexity grows.
- Communication fragility: decentralized cooperation is sensitive to packet loss, stale intent exchange, bandwidth limits, and asynchronous updates.
- Incomplete modeling of agent intent: many methods still rely on simplified assumptions about surrounding drivers, pedestrians, or mixed-autonomy behavior.
- Validation imbalance: simulation studies dominate, while hardware, vehicle-level experiments, and standardized safety metrics remain limited.
To make this validation gap more explicit, Table 5 summarizes the validation maturity levels observed across the reviewed safety-oriented MPC studies. The table is qualitative rather than count-based because the included papers report validation evidence with different levels of detail and non-uniform terminology.
Table 5.
Validation maturity levels in reviewed safety-oriented MPC studies.
From an engineering perspective, these limitations show that safety-oriented MPC should be evaluated not only by formulation or simulation performance but also by implementation evidence. Future studies should report solver type, sampling time, prediction horizon, hardware platform, average and worst-case computation time, warm-start strategy, infeasibility handling, and fallback control logic. Such reporting would make it easier to distinguish improvements caused by the MPC formulation itself from improvements caused by vehicle model fidelity, scenario design, solver configuration, or evaluation assumptions.
Taken together, these observations indicate that future progress depends not only on better optimization formulations but also on stronger evidence, more disciplined benchmarking, and tighter integration between controller design and realistic validation.
5. Future Research Directions
Future research on safety-oriented MPC should move from isolated controller refinements toward integrated, validation-aware system architectures. Across the three thematic domains, the most important directions are uncertainty-aware safety, bounded learning support, computation-aware design, standardized validation, and scalable interaction handling.
5.1. Risk-Sensitive and Adaptive Collision Avoidance
Future collision-avoidance research should move beyond nominal obstacle clearance toward uncertainty-aware emergency control that remains feasible under strict real-time limits. The most promising direction is hybrid robust-learning MPC, where model-based constraints define the safety envelope and data-driven components support prediction refinement, residual correction, or context adaptation without obscuring the safety logic.
Priority should also be given to computation-aware and interaction-aware design. Future studies should report solver timing, fallback behavior, degraded-operation logic, and controller response under perception loss, occlusion, intent uncertainty, mixed-autonomy behavior, or rapidly changing maneuver space.
5.2. Robust, Transparent, and Comfort-Aware Trajectory Tracking
Future trajectory tracking research should emphasize robust and interpretable adaptation that integrates tracking precision with comfort, fault tolerance, friction variation, and uncertainty-aware constraint handling. Learning-enhanced models should be evaluated with explicit safeguards and uncertainty bounds, while integrated lateral–longitudinal formulations should be tested under aggressive maneuvers, low-friction conditions, actuator limits, and disturbance recovery. Future studies should report comfort- and safety-related metrics together, including tracking error, lateral acceleration, jerk, yaw rate variation, constraint violation, computation time, and recovery behavior after disturbances.
5.3. Scalable and Interaction-Aware Coordination
Future coordination-oriented MPC should prioritize communication-resilient distributed architectures, interaction-aware prediction, and hierarchical decompositions that remain tractable as the number of agents increases. Coordination schemes should avoid assuming perfect cooperation or fully known intent; instead, they should represent negotiation, behavioral diversity, communication delay, packet loss, asynchronous updates, and imperfect intent prediction within the evaluation framework.
Standardized validation is also essential for this domain. Common scenario families, clearer safety metrics, and stronger reporting of computation and experiment design would make it easier to compare coordination methods and judge whether they can transfer from small, idealized networks to realistic mixed traffic.
In summary, future safety-oriented MPC research should combine model-based guarantees, uncertainty-aware prediction, bounded learning support, scalable coordination, and validation practices that more closely reflect real deployment conditions.
6. Conclusions
This paper reviewed 101 studies on safety-oriented MPC for autonomous vehicles and organized the evidence into three main domains: collision avoidance and risk mitigation, trajectory tracking and path following, and intersection/coordination tasks. The review confirms that MPC remains one of the most versatile control frameworks for AV safety because it can unify prediction, optimization, and constraint handling within a single decision structure.
At the same time, the literature is stronger in methodological diversity than in validation depth. The field has progressed from nominal and geometry-based designs toward robust, risk-aware, hierarchical, and learning-enhanced architectures, but many published gains are still demonstrated primarily in simulation and under non-uniform evaluation settings.
The most important barriers to deployment are recurring rather than isolated: limited real-time evidence for complex formulations, incomplete treatment of uncertainty, fragmented integration of perception and control, and weak scalability of cooperative schemes in realistic interactive traffic. These limitations show that the maturity of safety-oriented MPC should be judged not only by theoretical formulation or simulation performance but also by real-time feasibility, uncertainty propagation, system integration, and reproducible validation practice.
Accordingly, future research should prioritize hybrid system architectures that preserve interpretable safety logic while incorporating richer prediction, bounded learning support, and scalable coordination. Progress will depend not only on designing better MPC algorithms, but also on reporting stronger evidence through more rigorous benchmarking and more realistic validation.
Overall, this review provides a tightened synthesis of the current state of safety-oriented MPC for AVs and identifies the methodological shifts, persistent weaknesses, and most credible research directions for safer and more deployable autonomous driving systems.
Author Contributions
A.M. (conceptualization; methodology; investigation; data curation; formal analysis; software; visualization; writing—original draft). R.S. (validation; review and editing; supervision; project administration). All authors have read and agreed to the published version of the manuscript.
Funding
This research was funded by Obuda University, 1034 Budapest, 96/B Becsi Str, Hungary.
Data Availability Statement
The original contributions presented in this study are included in the article. Further inquiries can be directed to the corresponding author.
Acknowledgments
The authors thank the editors and anonymous reviewers for their valuable comments. AI-assisted tools were used for language editing and manuscript organization; the authors reviewed the output critically and take full responsibility for the final content.
Conflicts of Interest
The authors declare no conflicts of interest.
References
- Dong, D.; Ye, H.T.; Luo, W.G.; Wen, J.Y.; Huang, D. Collision Avoidance Path Planning and Tracking Control for Autonomous Vehicles Based on Model Predictive Control. Sensors 2024, 24, 5211. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Philippe, C.; Adouane, L.; Thuilot, B.; Tsourdos, A.; Shin, H.-S. Safe and Online MPC for Managing Safety and Comfort of Autonomous Vehicles in Urban Environment. In Proceedings of the 2018 21st International Conference on Intelligent Transportation Systems (ITSC), Maui, HI, USA, 4–7 November 2018; pp. 300–306. [Google Scholar] [CrossRef] [Scilit]
- Wang, J.; Gong, S.; Peeta, S.; Lu, L. A real-time deployable model predictive control-based cooperative platooning approach for connected and autonomous vehicles. Transp. Res. Part B Methodol. 2019, 128, 271–301. [Google Scholar] [CrossRef] [Scilit]
- Jiang, Y.; Man, Z.; Xia, K.; Wu, Y.; Wang, Y.; Yao, Z. Model predictive control-based cooperative lane-changing strategy for connected autonomous vehicle platoons merging into dedicated lanes. Expert Syst. Appl. 2025, 278, 127274. [Google Scholar] [CrossRef] [Scilit]
- Chen, H.; Zhang, X. Path Planning for Intelligent Vehicle Collision Avoidance of Dynamic Pedestrian Using Att-LSTM, MSFM, and MPC at Unsignalized Crosswalk. IEEE Trans. Ind. Electron. 2022, 69, 4285–4295. [Google Scholar] [CrossRef] [Scilit]
- Škugor, B.; Deur, J.; Ivanović, V.; Tseng, H.E. Safety Manifold for Stochastic Model Predictive Control of an Autonomous Vehicle Approaching Unsignalized Crosswalks with Pedestrians. In Proceedings of the 2024 International Conference on Smart Systems and Technologies (SST), Osijek, Croatia, 16–18 October 2024; pp. 279–285. [Google Scholar] [CrossRef] [Scilit]
- Cheng, S.; Li, L.; Guo, H.Q.; Chen, Z.G.; Song, P. Longitudinal Collision Avoidance and Lateral Stability Adaptive Control System Based on MPC of Autonomous Vehicles. IEEE Trans. Intell. Transp. Syst. 2020, 21, 2376–2385. [Google Scholar] [CrossRef] [Scilit]
- Zhang, Z.; Jiang, J.; Chen, W.-H. Unveiling the Road Ahead: An MPC-Based Approach for Autonomous Intersection Navigation with Occlusion. In Proceedings of the 2023 IEEE International Automated Vehicle Validation Conference (IAVVC), Austin, TX, USA, 16–18 October 2023; pp. 1–6. [Google Scholar] [CrossRef] [Scilit]
- Wang, Y.; Liu, Z.; Zuo, Z.; Li, Z.; Wang, L.; Luo, X. Trajectory Planning and Safety Assessment of Autonomous Vehicles Based on Motion Prediction and Model Predictive Control. IEEE Trans. Veh. Technol. 2019, 68, 8546–8556. [Google Scholar] [CrossRef] [Scilit]
- Yu, S.; Chen, B.; Jaimoukha, I.M.; Evangelou, S.A. Game-Theoretic Model Predictive Control for Safety-Assured Autonomous Vehicle Overtaking in Mixed-Autonomy Environment. In Proceedings of the 2024 European Control Conference (ECC), Stockholm, Sweden, 25–28 June 2024; pp. 3728–3733. [Google Scholar] [CrossRef] [Scilit]
- Fu, T.Z.; Nguyen, H.H.; Findeisen, R. Guaranteed Collision Avoidance for Autonomous Vehicles Fusing Model Predictive Control and Data Driven Reachability Analysis. In Proceedings of the 2024 European Control Conference (ECC), Stockholm, Sweden, 25–28 June 2024; pp. 2286–2291. [Google Scholar] [CrossRef] [Scilit]
- Ammour, M.; Orjuela, R.; Basset, M. A MPC Combined Decision Making and Trajectory Planning for Autonomous Vehicle Collision Avoidance. IEEE Trans. Intell. Transp. Syst. 2022, 23, 24805–24817. [Google Scholar] [CrossRef] [Scilit]
- Ammour, M.; Orjuela, R.; Basset, M. Collision avoidance for autonomous vehicle using MPC and time varying Sigmoid safety constraints. IFAC-Pap. 2021, 54, 39–44. [Google Scholar] [CrossRef] [Scilit]
- Yang, H.J.; He, Y.Q.; Xu, Y.; Zhao, H. Collision Avoidance for Autonomous Vehicles Based on MPC With Adaptive APF. IEEE Trans. Intell. Veh. 2024, 9, 1559–1570. [Google Scholar] [CrossRef] [Scilit]
- Shen, D.; Chen, Y.; Li, L.; Hu, J. Trajectory Tracking for Autonomous Vehicles Using Robust Model Predictive Control. IFAC-PapersOnLine 2024, 58, 94–101. [Google Scholar] [CrossRef] [Scilit]
- Zhao, W.; Wei, H.; Ai, Q.; Zheng, N.; Lin, C.; Zhang, Y. Real-time model predictive control of path-following for autonomous vehicles towards model mismatch and uncertainty. Control Eng. Pract. 2024, 153, 106126. [Google Scholar] [CrossRef] [Scilit]
- Zhang, Q.; Langari, R.; Tseng, H.E.; Mohan, S.; Szwabowski, S.; Filev, D. Stackelberg Differential Lane Change Game Based on MPC and Inverse MPC. IEEE Trans. Intell. Transp. Syst. 2024, 25, 8473. [Google Scholar] [CrossRef] [Scilit]
- Huang, L.; Panagou, D. Automated turning and merging for autonomous vehicles using a Nonlinear Model Predictive Control approach. In Proceedings of the 2017 American Control Conference (ACC), Seattle, WA, USA, 24–26 May 2017; pp. 5525–5531. [Google Scholar] [CrossRef] [Scilit]
- Dai, Q.; Liu, J.; Guo, H.; Chen, H.; Cao, D. Model Predictive Decision-Making Considering Lane-Changing Time Under Emergency Collision Avoidance for Intelligent Vehicles. IEEE Trans. Ind. Electron. 2024, 71, 11250. [Google Scholar] [CrossRef] [Scilit]
- Dixit, S.; Montanaro, U.; Dianati, M.; Oxtoby, D.; Mizutani, T.; Mouzakitis, A.; Fallah, S. Trajectory Planning for Autonomous High-Speed Overtaking in Structured Environments Using Robust MPC. IEEE Trans. Intell. Transp. Syst. 2020, 21, 2310. [Google Scholar] [CrossRef] [Scilit]
- Hu, C.; Xie, Y.; Xie, L.; Magno, M. Sparse Gaussian process-based strategies for two-layer model predictive control in autonomous vehicle drifting. Transp. Res. Part C Emerg. Technol. 2025, 174, 105065. [Google Scholar] [CrossRef] [Scilit]
- Wang, S.; Typaldos, P.; Li, C.; Malikopoulos, A.A. VisioPath: Vision-Language Enhanced Model Predictive Control for Safe Autonomous Navigation in Mixed Traffic. IEEE Open J. Control Syst. 2025, 4, 562. [Google Scholar] [CrossRef] [Scilit]
- Yang, Y.; Xu, Y.; Zhang, C.; Li, D.; Li, N. A Learning-Based Stochastic Model Predictive Control Method for Online Trajectory Control of Autonomous Vehicles at an Unsignalized Intersection. In Proceedings of the 2025 IEEE 19th International Conference on Control & Automation (ICCA), Tallinn, Estonia, 30 June–3 July 2025; pp. 336–341. [Google Scholar] [CrossRef] [Scilit]
- Bethge, J.; Pfefferkorn, M.; Rose, A.; Peters, J.; Findeisen, R. Model Predictive Control with Gaussian-Process-Supported Dynamical Constraints for Autonomous Vehicles. IFAC-PapersOnLine 2023, 56, 507–512. [Google Scholar] [CrossRef] [Scilit]
- Arrigoni, S.; Cheli, F.; Manazza, S.; Gottardis, P.; Happee, R.; Arat, M.; Kotiadis, D. Autonomous vehicle controlled by safety path planner with collision risk estimation coupled with a non-linear MPC. In Dynamics of Vehicles on Roads and Tracks; CRC Press: Boca Raton, FL, USA, 2016; pp. 199–208. [Google Scholar] [CrossRef] [Scilit]
- Song, Y.H.; Huh, K. Driving and steering collision avoidance system of autonomous vehicle with model predictive control based on non-convex optimization. Adv. Mech. Eng. 2021, 13, 16878140211027669. [Google Scholar] [CrossRef] [Scilit]
- Xiong, L.; Liu, M.; Yang, X.; Leng, B. Integrated Path Tracking for Autonomous Vehicle Collision Avoidance Based on Model Predictive Control With Multi-constraints. In Proceedings of the 2022 IEEE 25th International Conference on Intelligent Transportation Systems (ITSC), Macau, China, 8–12 October 2022; pp. 554–561. [Google Scholar] [CrossRef] [Scilit]
- Ko, C.; Han, S.; Choi, M.; Kim, K.-S. Integrated Path Planning and Tracking Control of Autonomous Vehicle for Collision Avoidance based on Model Predictive Control and Potential Field. In Proceedings of the 2020 20th International Conference on Control, Automation and Systems (ICCAS), Busan, Republic of Korea, 13–16 October 2020; pp. 956–961. [Google Scholar] [CrossRef] [Scilit]
- Zhang, Z.; Qin, J.; Tan, S.; Luo, H. Lane change trajectory planning based on improved model predictive control with artificial potential field for autonomous vehicles in medium-high speed scenarios. Eng. Appl. Artif. Intell. 2025, 150, 110601. [Google Scholar] [CrossRef] [Scilit]
- Soliman, M.; Morabito, B.; Findeisen, R. Towards Safe Exploration for Autonomous Vehicles using Dual Model Predictive Control. IFAC-PapersOnLine 2022, 55, 387–392. [Google Scholar] [CrossRef] [Scilit]
- Li, S.; Wang, S.; Lu, X.; Wang, S.; Tian, Y.; Guo, L. Path Tracking with Nonlinear Model Predictive Control Based on Tire Adhesion Margin. In Proceedings of the 2019 Chinese Automation Congress (CAC), Hangzhou, China, 22–24 November 2019; pp. 4907–4912. [Google Scholar] [CrossRef] [Scilit]
- Yang, W.; Su, Y.; Chen, Y.; Lian, C. Integrated Spatial Kinematics–Dynamics Model Predictive Control for Collision-Free Autonomous Vehicle Tracking. Actuators 2024, 13, 153. [Google Scholar] [CrossRef] [Scilit]
- Yang, Y.; Ning, M.; Huang, S.; Hashemi, E.; Khajepour, A. Intelligent Mobility System with Integrated Motion Planning and Control Utilizing Infrastructure Sensor Nodes. In Proceedings of the 2024 IEEE 27th International Conference on Intelligent Transportation Systems (ITSC), Edmonton, AB, Canada, 24–27 September 2024; pp. 1133–1138. [Google Scholar] [CrossRef] [Scilit]
- Dong, H.; Yu, H.; Xi, J. Real-Time Model Predictive Control for Simultaneous Drift and Trajectory Tracking of Autonomous Vehicles. In Proceedings of the 2022 6th CAA International Conference on Vehicular Control and Intelligence (CVCI), Nanjing, China, 28–30 October 2022. [Google Scholar] [CrossRef] [Scilit]
- Nan, J.; Ye, X.; Cao, W. Nonlinear Model Predictive Control with Terminal Cost for Autonomous Vehicles Trajectory Follow. Appl. Sci. 2022, 12, 11359. [Google Scholar] [CrossRef] [Scilit]
- Kim, M.; Lee, D.; Ahn, J.; Kim, M.; Park, J. Model Predictive Control Method for Autonomous Vehicles Using Time-Varying and Non-Uniformly Spaced Horizon. IEEE Access 2021, 9, 86475. [Google Scholar] [CrossRef] [Scilit]
- Bifulco, G.N.; Coppola, A.; Loizou, S.G.; Petrillo, A.; Santini, S. Combined Energy-oriented Path Following and Collision Avoidance approach for Autonomous Electric Vehicles via Nonlinear Model Predictive Control. In Proceedings of the 2021 IEEE International Conference on Environment and Electrical Engineering and 2021 IEEE Industrial and Commercial Power Systems Europe (EEEIC/I&CPS Europe), Bari, Italy, 7–10 September 2021. [Google Scholar] [CrossRef] [Scilit]
- Xiaohua, W.; Mingyu, H.; Zhiyuan, G.; Li, L.; Zhonghua, M. Path Tracking and Obstacle Avoidance Algorithm Based on Model Predictive Control. In Proceedings of the 2022 34th Chinese Control and Decision Conference (CCDC), Hefei, China, 15–17 August 2022; pp. 2402–2407. [Google Scholar] [CrossRef] [Scilit]
- Liu, B.; Wang, Z.; Guo, H.; Zhang, G. Improved Model Predictive Control Path Tracking Approach Based on Online Updated Algorithm with Fuzzy Control and Variable Prediction Time Domain for Autonomous Vehicles. World Electr. Veh. J. 2024, 15, 257. [Google Scholar] [CrossRef] [Scilit]
- Jeong, Y.; Yim, S. Model Predictive Control-Based Integrated Path Tracking and Velocity Control for Autonomous Vehicle with Four-Wheel Independent Steering and Driving. Electronics 2021, 10, 2812. [Google Scholar] [CrossRef] [Scilit]
- Nezami, M.; Männel, G.; Abbas, H.S.; Schildbach, G. A Safe Control Architecture Based on a Model Predictive Control Supervisor for Autonomous Driving. In Proceedings of the 2021 European Control Conference (ECC), Delft, The Netherlands, 29 June–2 July 2021; pp. 1297–1302. [Google Scholar] [CrossRef] [Scilit]
- Lin, S.-L.; Lin, B.-C. Enhancing Safety in Autonomous Vehicle Navigation: An Optimized Path Planning Approach Leveraging Model Predictive Control. Comput. Mater. Contin. 2024, 80, 3555–3572. [Google Scholar] [CrossRef] [Scilit]
- Wang, J.R.; Guo, Y.B.; Wang, Q.F.; Gao, J.; Chen, Y.M. Event-triggered MPC for Collision Avoidance of Autonomous Vehicles Considering Trajectory Tracking Performance. In Proceedings of the 2022 International Conference on Advanced Robotics and Mechatronics (ICARM), Guilin, China, 9–11 July 2022; pp. 514–520. [Google Scholar] [CrossRef] [Scilit]
- Chen, H.; Liu, Q.; Sun, D.; Yu, S.; Chen, H. Fast Model Predictive Control Trajectory Tracking for Autonomous Vehicles Based on BFGS Interior Point Method. IFAC-PapersOnLine 2024, 58, 433–438. [Google Scholar] [CrossRef] [Scilit]
- Nan, J.; Ge, Z.; Ye, X.; Burke, A.F.; Zhao, J. Model predictive control for autonomous vehicle path tracking through optimized kinematics. Results Eng. 2024, 24, 103123. [Google Scholar] [CrossRef] [Scilit]
- Mizushima, Y.; Okawa, I.; Nonaka, K. Model Predictive Control for Autonomous Vehicles with Speed Profile Shaping. IFAC-PapersOnLine 2019, 52, 31–36. [Google Scholar] [CrossRef] [Scilit]
- Awad, N.; Lasheen, A.; Elnaggar, M.; Kamel, A. Model predictive control with fuzzy logic switching for path tracking of autonomous vehicles. ISA Trans. 2022, 129, 193–205. [Google Scholar] [CrossRef] [Scilit]
- Sun, X.; Cai, Y.; Wang, S.; Xu, X.; Chen, L. Optimal control of intelligent vehicle longitudinal dynamics via hybrid model predictive control. Robot. Auton. Syst. 2019, 112, 190–200. [Google Scholar] [CrossRef] [Scilit]
- Elsisi, M. Optimal design of adaptive model predictive control based on improved GWO for autonomous vehicle considering system vision uncertainty. Appl. Soft Comput. 2024, 158, 111581. [Google Scholar] [CrossRef] [Scilit]
- Hung, N.T.; Crasta, N.; Moreno-Salinas, D.; Pascoal, A.M.; Johansen, T.A. Range-based target localization and pursuit with autonomous vehicles: An approach using posterior CRLB and model predictive control. Robot. Auton. Syst. 2020, 132, 103608. [Google Scholar] [CrossRef] [Scilit]
- Kovacs, A.; Vajk, I. Tuning parameter-free model predictive control with nonlinear internal model control structure for vehicle lateral control. Acta Polytech. Hung. 2023, 20, 185–204. [Google Scholar] [CrossRef] [Scilit]
- Zarrouki, B.; Nunes, J.; Betz, J. R2NMPC: A Real-Time Reduced Robustified Nonlinear Model Predictive Control with Ellipsoidal Uncertainty Sets for Autonomous Vehicle Motion Control. IFAC-PapersOnLine 2024, 58, 309–316. [Google Scholar] [CrossRef] [Scilit]
- Sun, C.; Zhang, X.; Xi, L.; Tian, Y. Design of a Path-Tracking Steering Controller for Autonomous Vehicles. Energies 2018, 11, 1451. [Google Scholar] [CrossRef] [Scilit]
- Yao, Q.; Tian, Y. A Model Predictive Controller with Longitudinal Speed Compensation for Autonomous Vehicle Path Tracking. Appl. Sci. 2019, 9, 4739. [Google Scholar] [CrossRef] [Scilit]
- Geng, K.; Liu, S. Robust Path Tracking Control for Autonomous Vehicle Based on a Novel Fault Tolerant Adaptive Model Predictive Control Algorithm. Appl. Sci. 2020, 10, 6249. [Google Scholar] [CrossRef] [Scilit]
- Geng, K.; Chulin, N.A.; Wang, Z. Fault-Tolerant Model Predictive Control Algorithm for Path Tracking of Autonomous Vehicle. Sensors 2020, 20, 4245. [Google Scholar] [CrossRef] [Scilit]
- Yu, Z.; Zhao, R.; Yuan, T. Lateral-Stability-Oriented Path-Tracking Control Design for Four-Wheel Independent Drive Autonomous Vehicles with Tire Dynamic Characteristics under Extreme Conditions. World Electr. Veh. J. 2024, 15, 465. [Google Scholar] [CrossRef] [Scilit]
- Jeong, Y.; Yim, S. Integrated Path Tracking and Lateral Stability Control with Four-Wheel Independent Steering for Autonomous Electric Vehicles on Low Friction Roads. Machines 2022, 10, 650. [Google Scholar] [CrossRef] [Scilit]
- Zhu, G.; Hong, W. NMPC-Based Path Tracking Control Through Cascaded Discretization Method and Steering Stability for 4WS Autonomous Vehicles Under Extreme Conditions. World Electr. Veh. J. 2024, 15, 573. [Google Scholar] [CrossRef] [Scilit]
- Guo, J.; Xie, Z.; Liu, M.; Hu, J.; Dai, Z.; Guo, J. Data-Driven Enhancements for MPC-Based Path Tracking Controller in Autonomous Vehicles. Sensors 2024, 24, 7657. [Google Scholar] [CrossRef] [Scilit]
- Zhang, D.; Chen, B. Path Planning and Predictive Control of Autonomous Vehicles for Obstacle Avoidance. In Proceedings of the 2022 18th IEEE/ASME International Conference on Mechatronic and Embedded Systems and Applications (MESA), Taipei, Taiwan, 28–30 November 2022. [Google Scholar] [CrossRef] [Scilit]
- Atsuta, K.; Honda, K.; Okuda, H.; Suzuki, T. LVLM-MPC Collaboration for Autonomous Driving: A Safety-Aware and Task-Scalable Control Architecture. In Proceedings of the 2025 IEEE 28th International Conference on Intelligent Transportation Systems (ITSC), Gold Coast, Australia, 18–21 November 2025; pp. 3030–3037. [Google Scholar] [CrossRef] [Scilit]
- Ibrahim, M.; Kögel, M.; Kallies, C.; Findeisen, R. Contract-based Hierarchical Model Predictive Control and Planning for Autonomous Vehicle. IFAC-PapersOnLine 2020, 53, 15758–15764. [Google Scholar] [CrossRef] [Scilit]
- Ibrahim, M.; Matschek, J.; Morabito, B.; Findeisen, R. Hierarchical Model Predictive Control for Autonomous Vehicle Area Coverage. IFAC-PapersOnLine 2019, 52, 79–84. [Google Scholar] [CrossRef] [Scilit]
- Mihály, A.; Farkas, Z.; Gáspár, P. Model Predictive Control for the Coordination of Autonomous Vehicles at Intersections. IFAC-PapersOnLine 2020, 53, 15174–15179. [Google Scholar] [CrossRef] [Scilit]
- Nikkhah, M.N.; Khastavan, A.; Nahvi, A. Nonlinear Model Predictive Control for High-Speed Collision Avoidance in Autonomous Vehicles. In Proceedings of the 2023 11th RSI International Conference on Robotics and Mechatronics (ICRoM), Tehran, Iran, 19–21 December 2023; pp. 769–775. [Google Scholar] [CrossRef] [Scilit]
- Reda, A.; Bouzid, A.; Vásárhelyi, J. Model predictive control for automated vehicle steering. Acta Polytech. Hung. 2020, 17, 163–182. [Google Scholar] [CrossRef] [Scilit]
- Stano, P.; Tavernini, D.; Montanaro, U.; Tufo, M.; Fiengo, G.; Novella, L.; Sorniotti, A. Enhanced Active Safety Through Integrated Autonomous Drifting and Direct Yaw Moment Control via Nonlinear Model Predictive Control. IEEE Trans. Intell. Veh. 2024, 9, 4172. [Google Scholar] [CrossRef] [Scilit]
- Dutta, A.; Misra, A.; Tukaria, R.; Deka, S.; Sarma, K.K. Using Model Predictive Control for Collision Avoidance During Lane Change Maneuvers in Autonomous Vehicles. Int. J. Softw. Sci. Comput. Intell. 2025, 17, 1–21. [Google Scholar] [CrossRef] [Scilit]
- Shao, C.; Duan, X.; Zhou, J.; Zhao, D. Trajectory Planning for Autonomous Overtaking on Curved Roads with Avoidance of Human Driving Vehicles and Static Obstacles. In Proceedings of the 2023 IEEE International Conference on Unmanned Systems (ICUS), Hefei, China, 13–15 October 2023; pp. 1–5. [Google Scholar] [CrossRef] [Scilit]
- Toy, I.; Yusefi, A.; Durdu, A. Model Predictive Control for Reliable and Efficient Path Tracking in Autonomous Vehicles. In Proceedings of the 2025 9th International Symposium on Innovative Approaches in Smart Technologies (ISAS), Gaziantep, Turkiye, 27–28 June 2025; pp. 1–4. [Google Scholar] [CrossRef] [Scilit]
- Liu, H.; Sun, J.; Cheng, K.W.E. A Two-Layer Model Predictive Path-Tracking Control With Curvature Adaptive Method for High-Speed Autonomous Driving. IEEE Access 2023, 11, 89228. [Google Scholar] [CrossRef] [Scilit]
- An, G.; Talebpour, A. Vehicle Platooning for Merge Coordination in a Connected Driving Environment: A Hybrid ACC-DMPC Approach. IEEE Trans. Intell. Transp. Syst. 2023, 24, 5239. [Google Scholar] [CrossRef] [Scilit]
- Yan, Y.; Wang, J.; Zhang, K.; Liu, Y.; Liu, Y.; Yin, G. Driver’s Individual Risk Perception-Based Trajectory Planning: A Human-Like Method. IEEE Trans. Intell. Transp. Syst. 2022, 23, 20413. [Google Scholar] [CrossRef] [Scilit]
- Farkas, Z.; Mihály, A.; Gáspár, P. MPC Control Strategy for Autonomous Vehicles Driving in Roundabouts. In Proceedings of the 2022 30th Mediterranean Conference on Control and Automation (MED), Vouliagmeni, Greece, 28 June–1 July 2022; pp. 939–944. [Google Scholar] [CrossRef] [Scilit]
- Yi, W.; Zhang, Z.; Huang, W.; Wang, H.; Huang, J.; Wang, Y. Enhanced Adaptive Cruise Control Strategy for Improving Driving Safety in Connected Vehicle Environment. In Proceedings of the 2021 6th International Conference on Transportation Information and Safety (ICTIS), Wuhan, China, 22–24 October 2021; pp. 805–810. [Google Scholar] [CrossRef] [Scilit]
- Caiazzo, B.; Coppola, A.; Petrillo, A.; Santini, S. Distributed Nonlinear Model Predictive Control for Connected Autonomous Electric Vehicles Platoon with Distance-Dependent Air Drag Formulation. Energies 2021, 14, 5122. [Google Scholar] [CrossRef] [Scilit]
- Wang, Z. Research on Cooperative Control Algorithm for S-Curve Trajectory Tracking and Dynamic Obstacle Avoidance of Autonomous Vehicles Based on MPC. In Proceedings of the 2025 5th International Conference on Artificial Intelligence, Robotics, and Communication (ICAIRC), Xiamen, China, 7–9 November 2025; pp. 619–623. [Google Scholar] [CrossRef] [Scilit]
- Chen, Z.; Lai, J.; Li, P.; Awad, O.I.; Zhu, Y. Prediction Horizon-Varying Model Predictive Control (MPC) for Autonomous Vehicle Control. Electronics 2024, 13, 1442. [Google Scholar] [CrossRef] [Scilit]
- Muraleedharan, A.; Okuda, H.; Suzuki, T. Real-Time Implementation of Randomized Model Predictive Control for Autonomous Driving. IEEE Trans. Intell. Veh. 2022, 7, 11. [Google Scholar] [CrossRef] [Scilit]
- Bono, A.; Fedele, G.; Franzè, G. A Swarm-Based Distributed Model Predictive Control Scheme for Autonomous Vehicle Formations in Uncertain Environments. IEEE Trans. Cybern. 2022, 52, 8876. [Google Scholar] [CrossRef] [Scilit]
- Hung, N.T.; Pascoal, A.M. Cooperative Path Following of Autonomous Vehicles with Model Predictive Control and Event Triggered Communications. IFAC-PapersOnLine 2018, 51, 562–567. [Google Scholar] [CrossRef] [Scilit]
- Du, R.; Chen, S.; Li, Y.; Ha, P.Y.J.; Dong, J.; Anastasopoulos, P.C.; Labi, S. A Cooperative Crash Avoidance Framework for Autonomous Vehicle under Collision-Imminent Situations in Mixed Traffic Stream. In Proceedings of the 2021 IEEE International Intelligent Transportation Systems Conference (ITSC), Indianapolis, IN, USA, 19–22 September 2021; pp. 1997–2002. [Google Scholar] [CrossRef] [Scilit]
- Scheffe, P.; Pedrosa, M.V.A.; Flaßkamp, K.; Alrifaee, B. Receding Horizon Control Using Graph Search for Multi-Agent Trajectory Planning. IEEE Trans. Control Syst. Technol. 2023, 31, 1092. [Google Scholar] [CrossRef] [Scilit]
- Lin, P.; Quan, Y.S.; Yang, J.H.; Chung, C.C.; Tsukada, M. Safety Tunnel-Based Model Predictive Path-Planning Controller With Potential Functions for Emergency Navigation. IEEE Trans. Intell. Transp. Syst. 2023, 24, 3974. [Google Scholar] [CrossRef] [Scilit]
- Yu, Z.; Han, P.; Leng, B.; Liu, M.; Xiong, L.; Li, B. An Emergency Collision-Avoidance Controller for Distributed Drive Autonomous Vehicles Based on AFS and DYC. In Proceedings of the 2023 35th Chinese Control and Decision Conference (CCDC), Yichang, China, 20–22 May 2023; pp. 175–181. [Google Scholar] [CrossRef] [Scilit]
- Shao, K.; Zhu, Y.; Xia, W.; Jiang, J.; Sun, C.; Liu, Y. Obstacle Avoidance and Path Tracking for Mpc Autonomous Vehicle Based on Improved Apf. In Proceedings of the 2025 37th Chinese Control and Decision Conference (CCDC), Xiamen, China, 16–19 May 2025; pp. 677–683. [Google Scholar] [CrossRef] [Scilit]
- Xu, T.; Yuan, H. Autonomous vehicle active safety system based on path planning and predictive control. In Proceedings of the 2016 35th Chinese Control Conference (CCC), Chengdu, China, 27–29 July 2016; pp. 8889–8895. [Google Scholar] [CrossRef] [Scilit]
- Liang, W.; Xing, H. Investigations on Speed Planning Algorithm and Trajectory Tracking Control of Intersection Scenarios Without Traffic Signs. IEEE Access 2023, 11, 8467. [Google Scholar] [CrossRef] [Scilit]
- Viana, Í.B.; Kanchwala, H.; Aouf, N. Cooperative Trajectory Planning for Autonomous Driving Using Nonlinear Model Predictive Control. In Proceedings of the 2019 IEEE International Conference on Connected Vehicles and Expo (ICCVE), Graz, Austria, 4–8 November 2019. [Google Scholar] [CrossRef] [Scilit]
- Viana, Í.B.; Aouf, N. Distributed Cooperative Path-Planning for Autonomous Vehicles Integrating Human Driver Trajectories. In Proceedings of the 2018 International Conference on Intelligent Systems (IS), Funchal, Portugal, 25–27 September 2018; pp. 655–661. [Google Scholar] [CrossRef] [Scilit]
- Sabouni, E.; Ahmad, H.M.S.; Cassandras, C.G.; Li, W. Merging Control in Mixed Traffic with Safety Guarantees: A Safe Sequencing Policy with Optimal Motion Control. In Proceedings of the 2023 IEEE 26th International Conference on Intelligent Transportation Systems (ITSC), Bilbao, Spain, 24–28 September 2023; pp. 4260–4265. [Google Scholar] [CrossRef] [Scilit]
- Abdeselam, N.; Gutiérrez-Moreno, R.; López-Guillén, E.; Barea, R.; Montiel-Marín, S.; Bergasa, L.M. Hybrid MPC and Spline-Based Controller for Lane Change Maneuvers in Autonomous Vehicles. In Proceedings of the 2023 IEEE 26th International Conference on Intelligent Transportation Systems (ITSC), Bilbao, Spain, 18–24 September 2023; pp. 3784–3789. [Google Scholar] [CrossRef] [Scilit]
- Beaune, C.; Héry, E.; Frémont, V. Risk-Aware Nonlinear Model Predictive Control for Autonomous Navigation: Confidence-Based Obstacle Constraints and Time-to-Collision Safe Trajectory Planning. In Proceedings of the 2025 IEEE Intelligent Vehicles Symposium (IV), Cluj-Napoca, Romania, 22–25 June 2025; pp. 1633–1639. [Google Scholar] [CrossRef] [Scilit]
- Farkas, Z.; Mihály, A.; Gáspár, P. Model Predictive Control Method for Autonomous Vehicles in Roundabouts. Machines 2023, 11, 75. [Google Scholar] [CrossRef] [Scilit]
- Hajiloo, R.; Abroshan, M.; Khajepour, A.; Kasaiezadeh, A.; Chen, S.-K. Integrated Steering and Differential Braking for Emergency Collision Avoidance in Autonomous Vehicles. IEEE Trans. Intell. Transp. Syst. 2021, 22, 3167. [Google Scholar] [CrossRef] [Scilit]
- Wurts, J.; Stein, J.L.; Ersal, T. Collision Imminent Steering at High Speeds on Curved Roads Using One-Level Nonlinear Model Predictive Control. IEEE Access 2021, 9, 39292. [Google Scholar] [CrossRef] [Scilit]
- Babu, M.; Oza, Y.; Singh, A.K.; Krishna, K.M.; Medasani, S. Model Predictive Control for Autonomous Driving Based on Time Scaled Collision Cone. In Proceedings of the 2018 European Control Conference (ECC), Limassol, Cyprus, 12–15 June 2018; p. 641. [Google Scholar] [CrossRef] [Scilit]
- Jiang, H.; Wang, Z.; Chen, Q.; Zhu, J. Obstacle avoidance of autonomous vehicles with CQP-based model predictive control. In Proceedings of the 2016 IEEE International Conference on Systems, Man, and Cybernetics (SMC), Budapest, Hungary, 9–12 October 2016; pp. 001668–001673. [Google Scholar] [CrossRef] [Scilit]
- Li, S.; Wang, S.; Li, Z.; Wang, S.; Tian, Y.; Guo, L. Model Predictive Control-based Path Tracking Using Steering Torque. In Proceedings of the 2019 Chinese Automation Congress (CAC), Hangzhou, China, 22–24 October 2019; pp. 4848–4853. [Google Scholar] [CrossRef] [Scilit]
- Zuo, Z.; Guo, S.; Wang, Y.; Li, Z. Risk Assessment and Trajectory Planning for Overtaking of Autonomous Vehicles on Two-lane Two-way Roads. In Proceedings of the 2022 41st Chinese Control Conference (CCC), Hefei, China, 25–27 July 2022; pp. 5481–5486. [Google Scholar] [CrossRef] [Scilit]
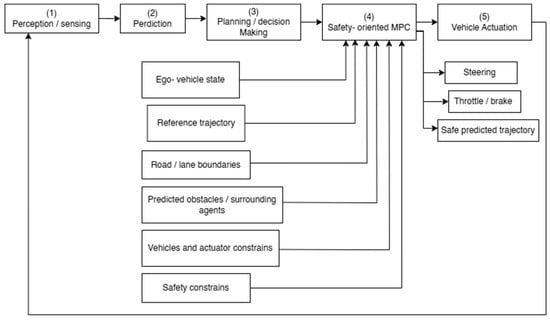
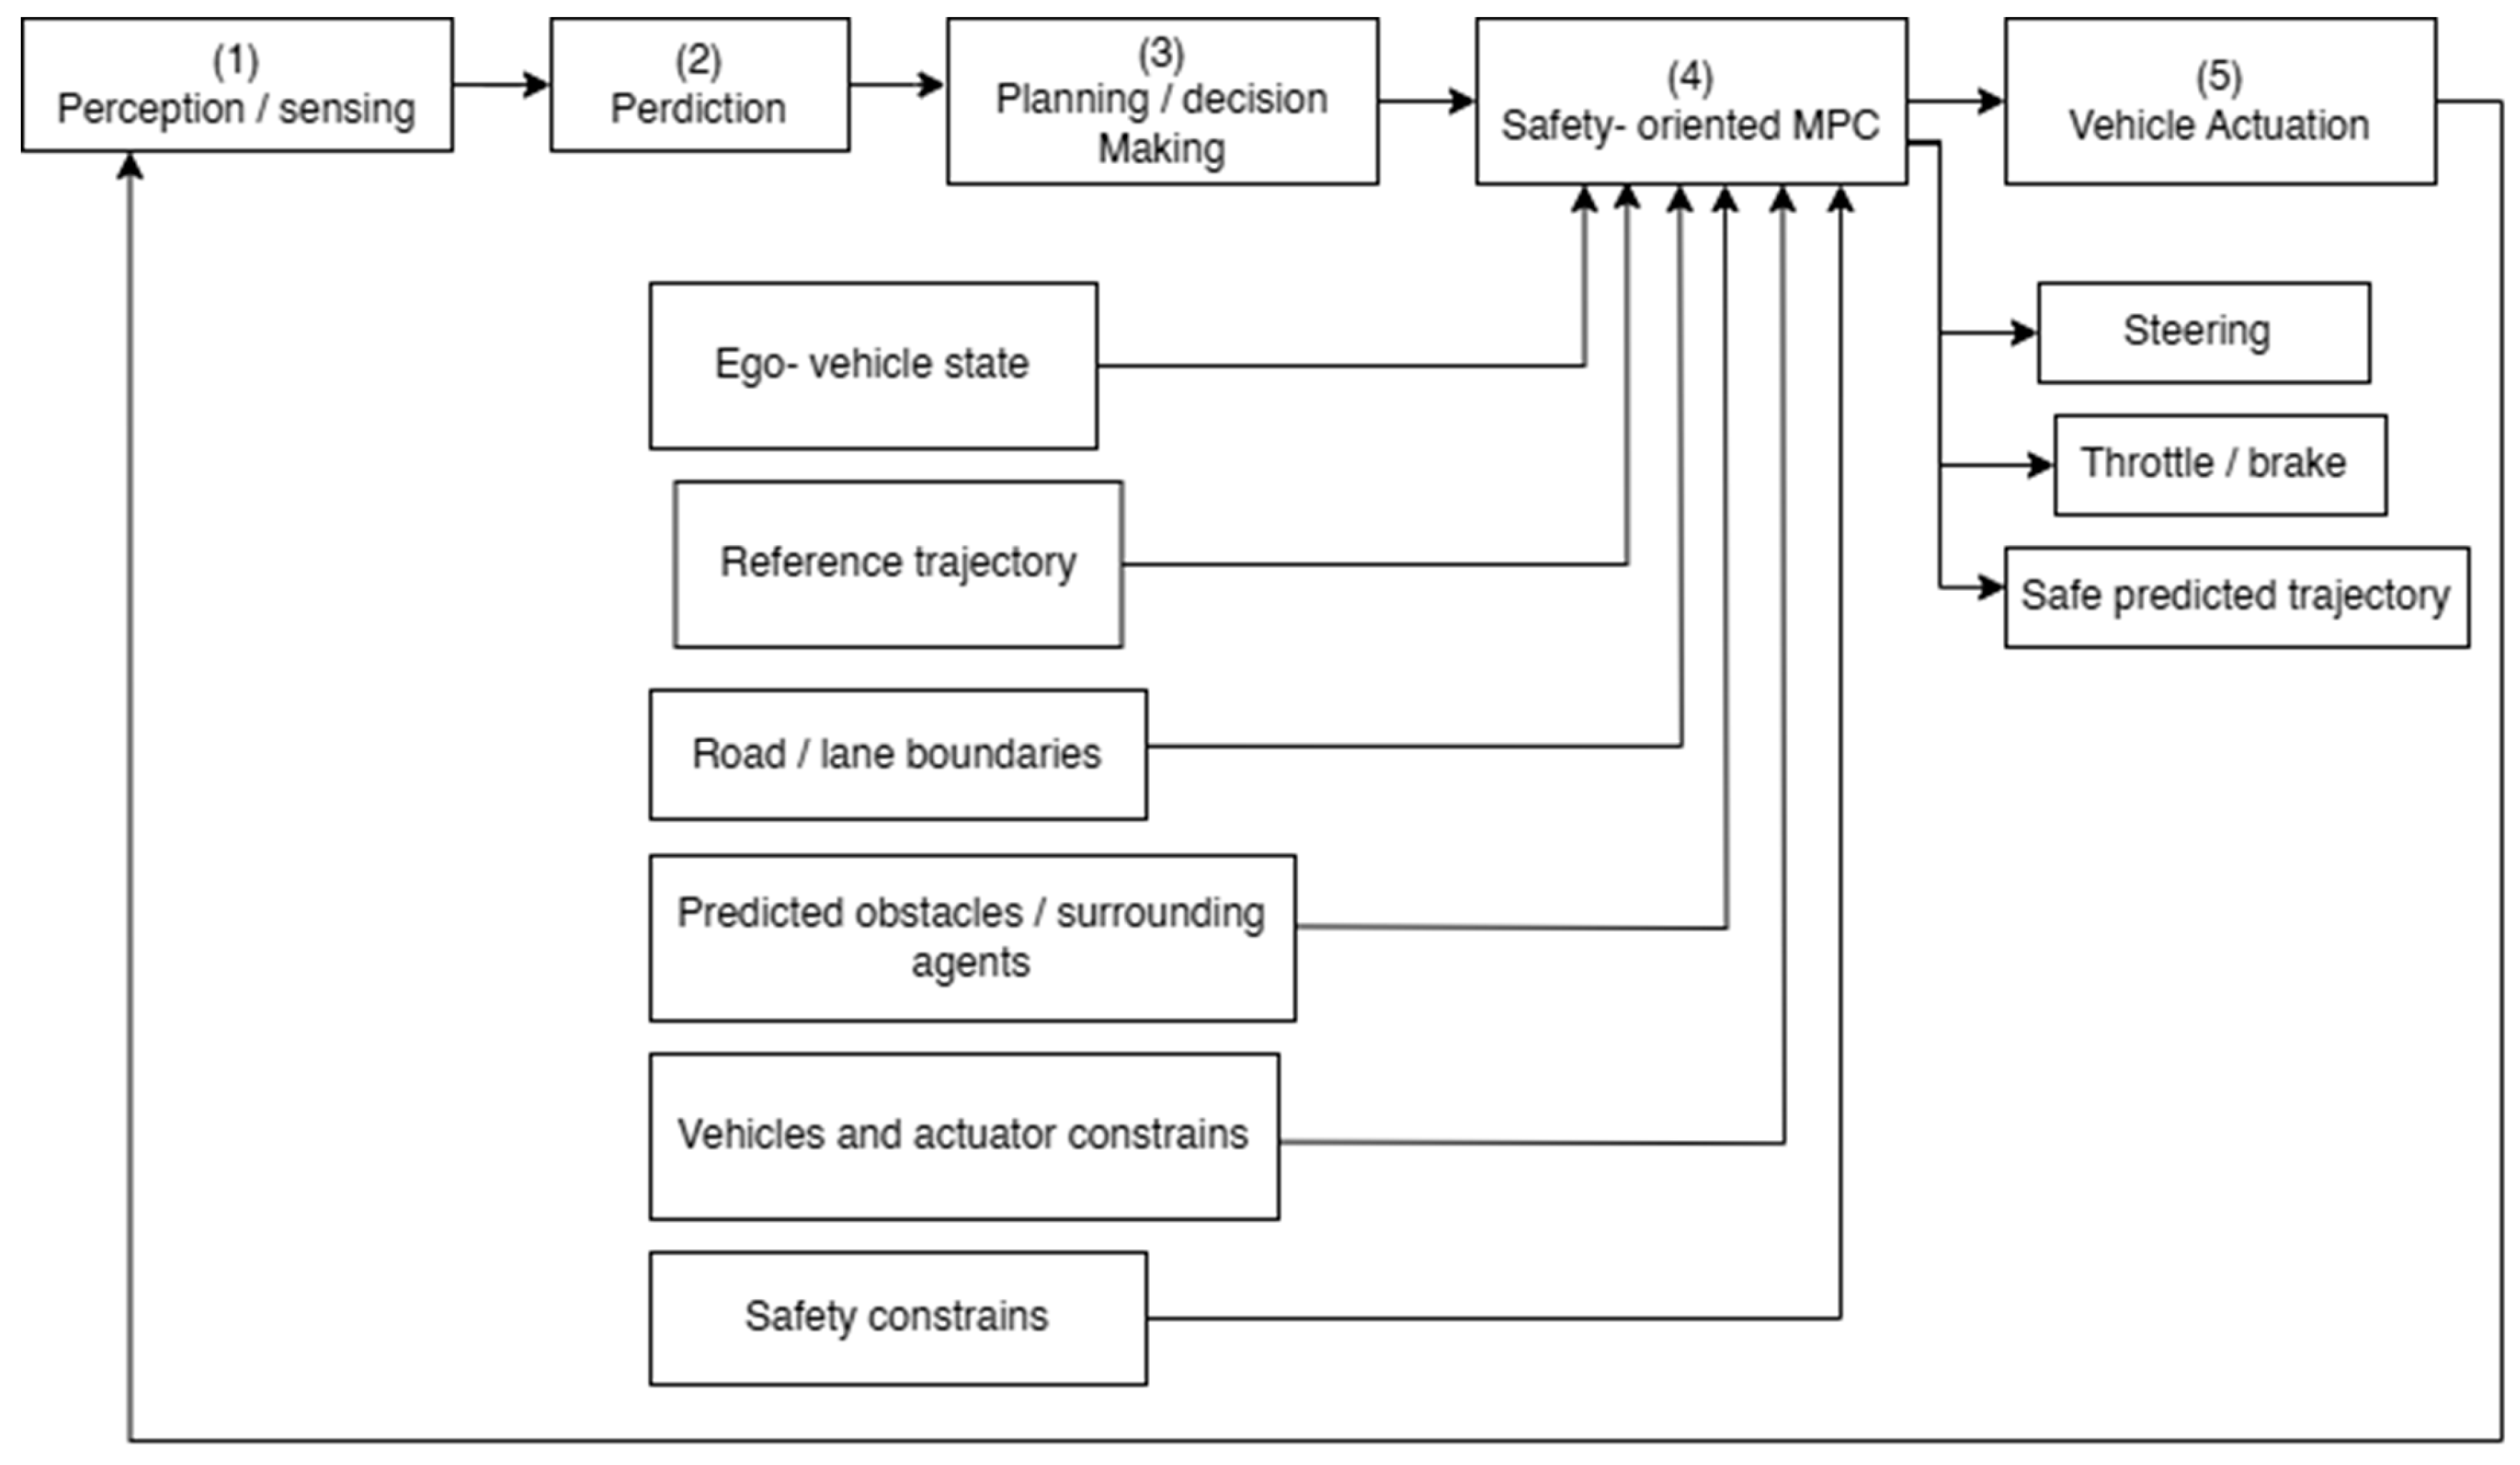
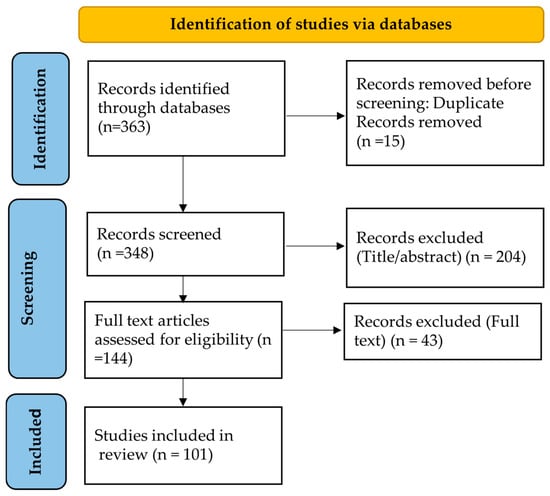
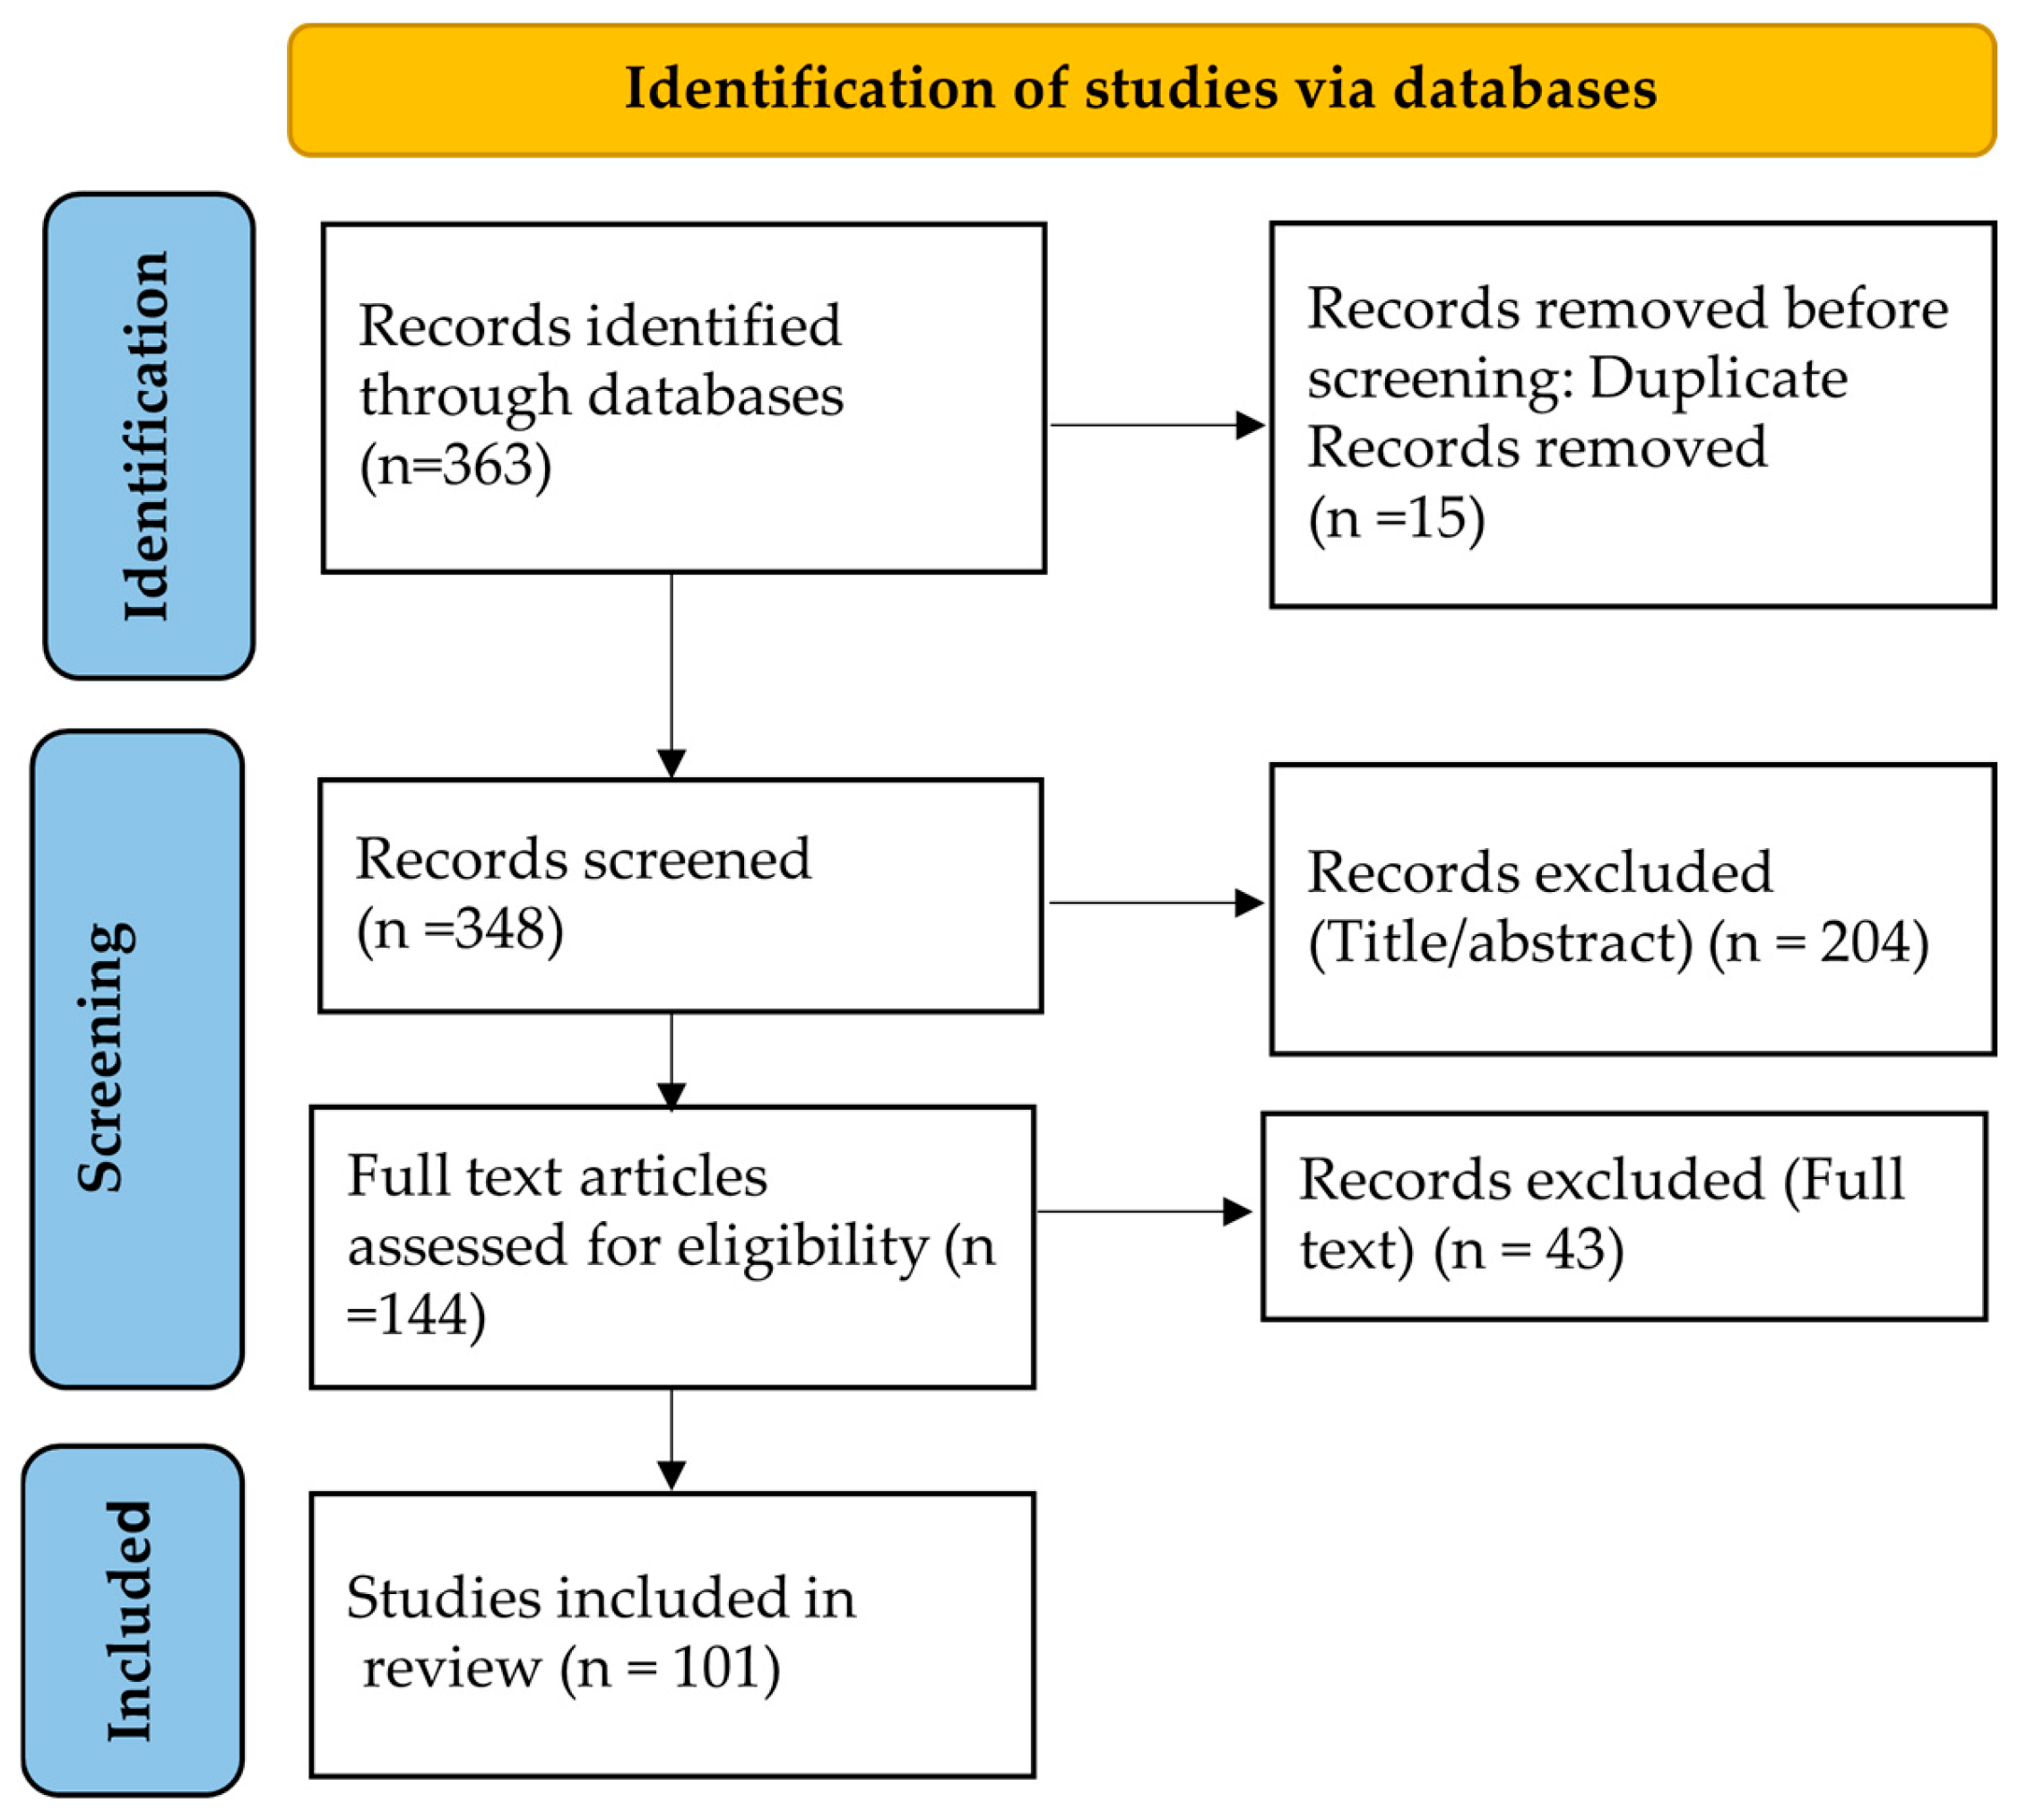
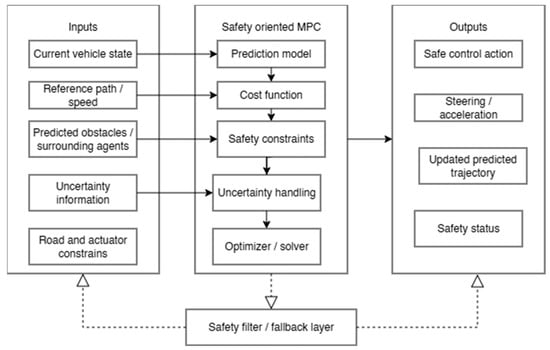
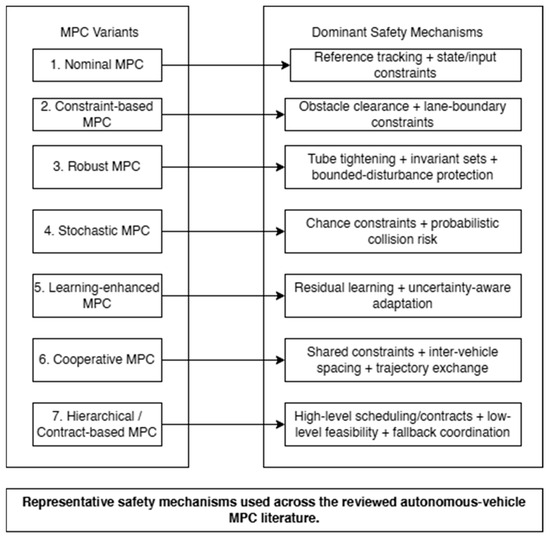

Disclaimer/Publisher’s Note: The statements, opinions and data contained in all publications are solely those of the individual author(s) and contributor(s) and not of MDPI and/or the editor(s). MDPI and/or the editor(s) disclaim responsibility for any injury to people or property resulting from any ideas, methods, instructions or products referred to in the content. |
© 2026 by the authors. Licensee MDPI, Basel, Switzerland. This article is an open access article distributed under the terms and conditions of the Creative Commons Attribution (CC BY) license.