Article

Path-Following Control of Small Fixed-Wing UAVs under Wind Disturbance

1
School of Aerospace Engineering, North University of China, Taiyuan 030051, China
2
College of Mechatronics Engineering, North University of China, Taiyuan 030051, China
*
Author to whom correspondence should be addressed.
Drones 2023, 7(4), 253; https://doi.org/10.3390/drones7040253
Submission received: 28 February 2023 / Revised: 23 March 2023 / Accepted: 6 April 2023 / Published: 7 April 2023

Abstract

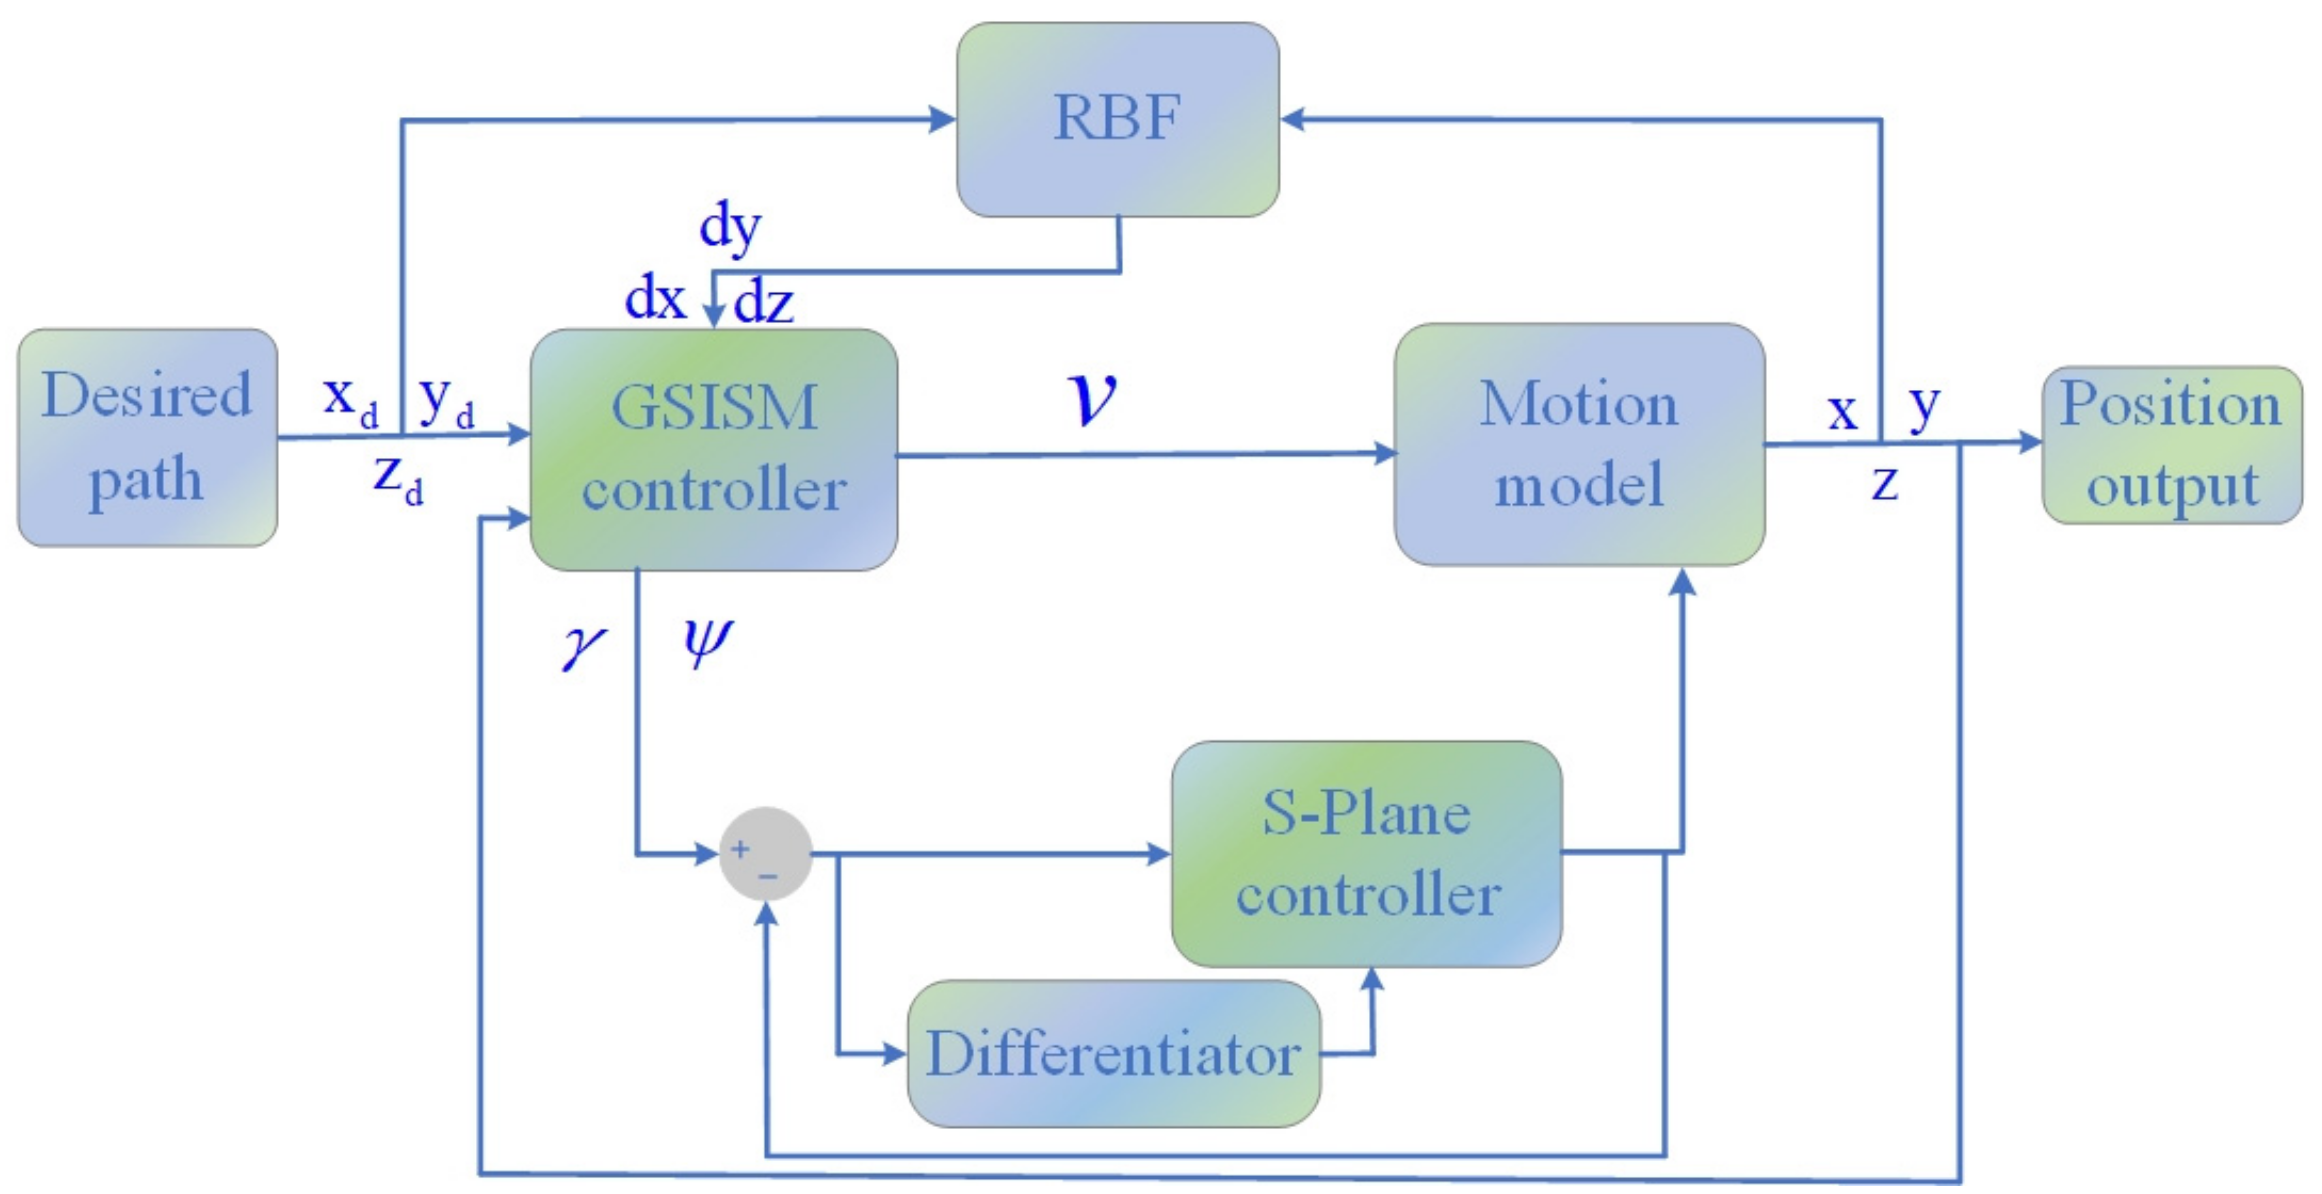
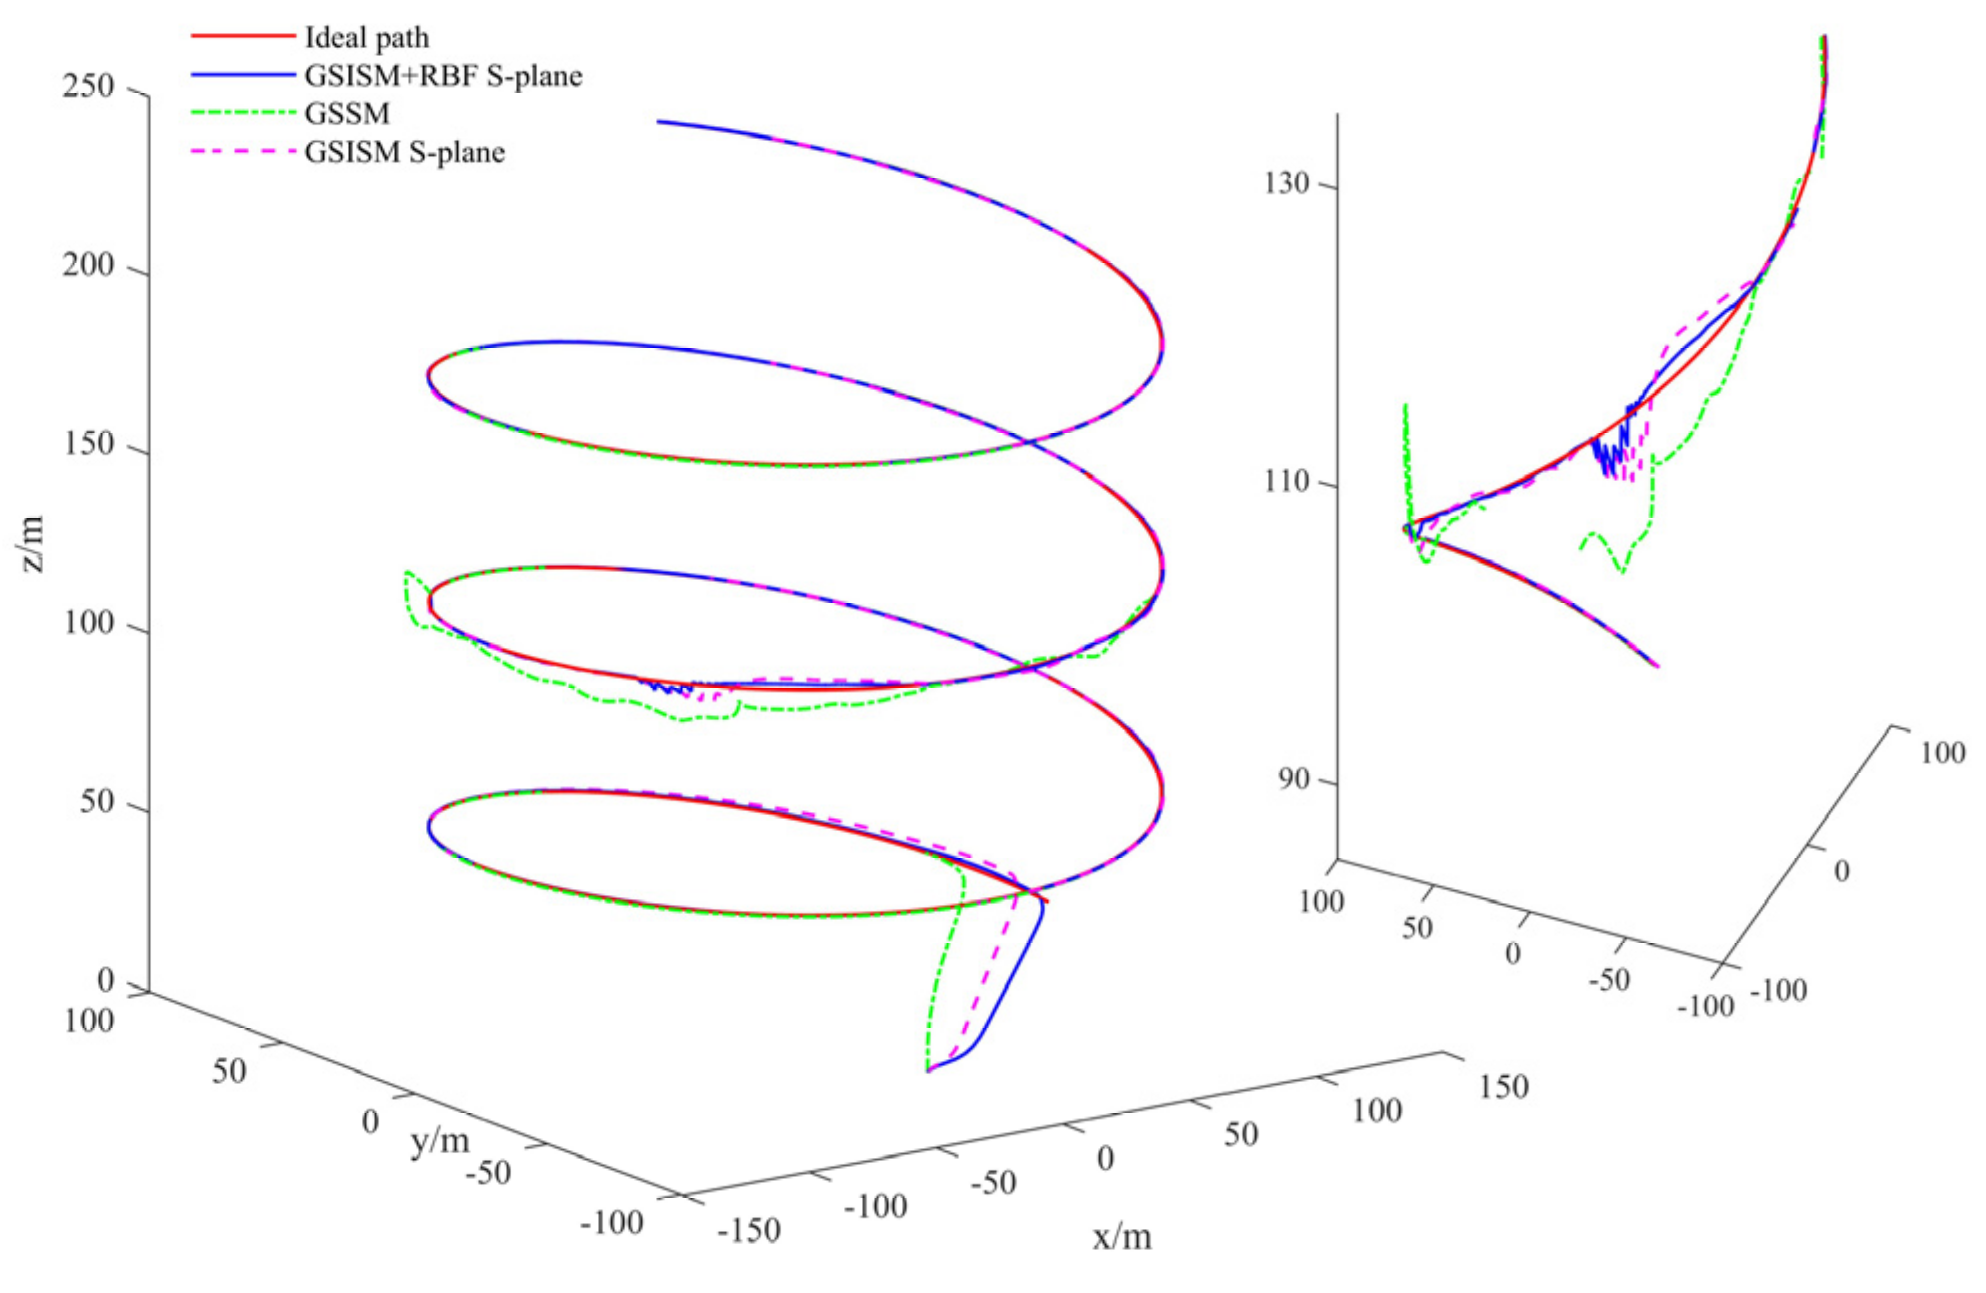
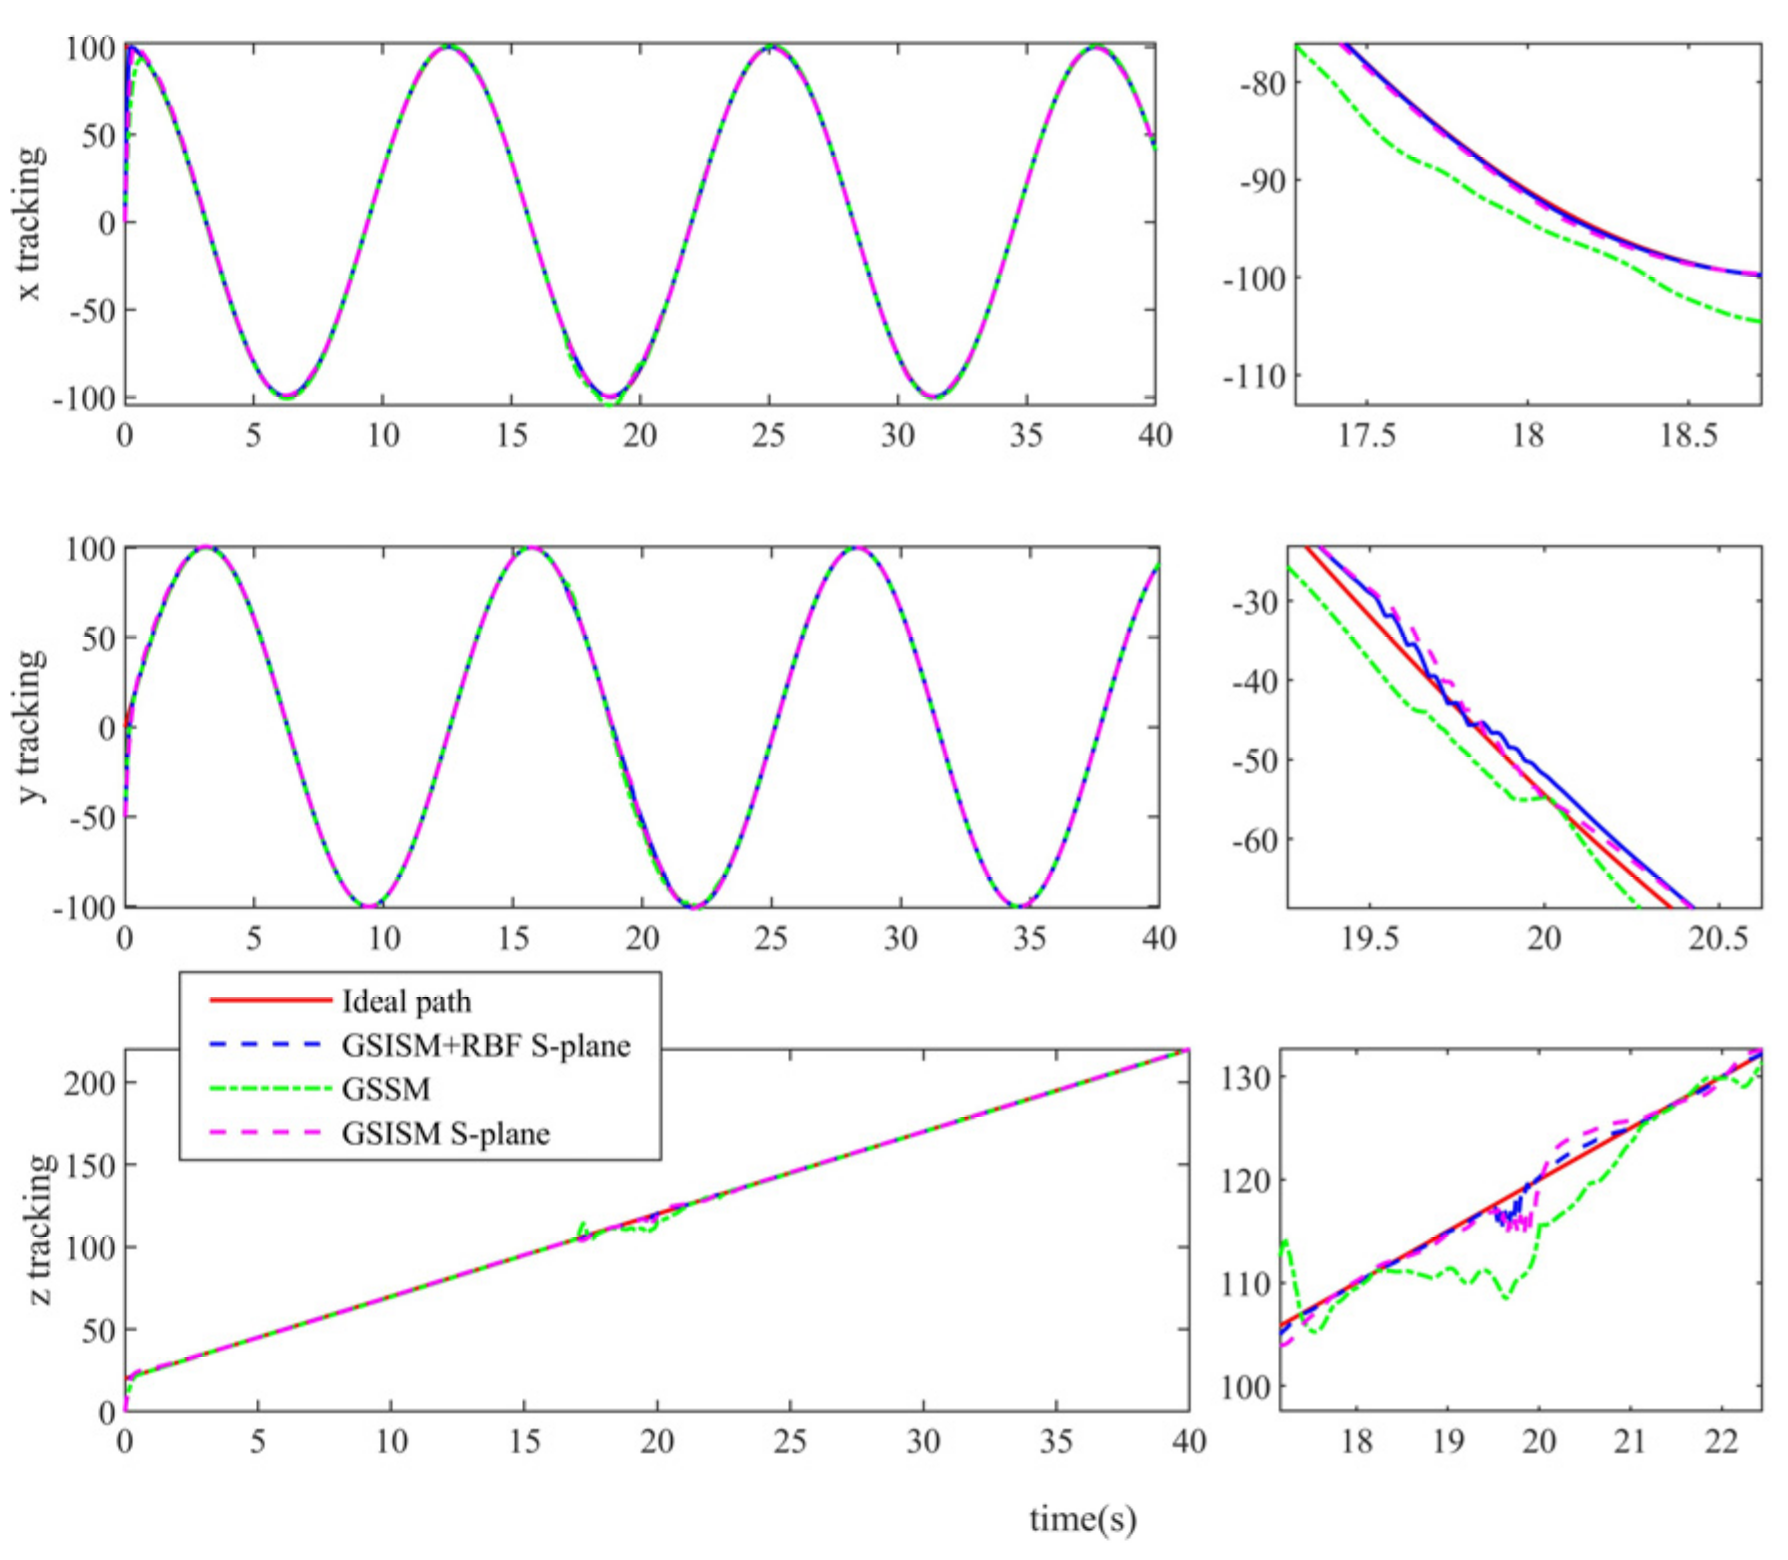
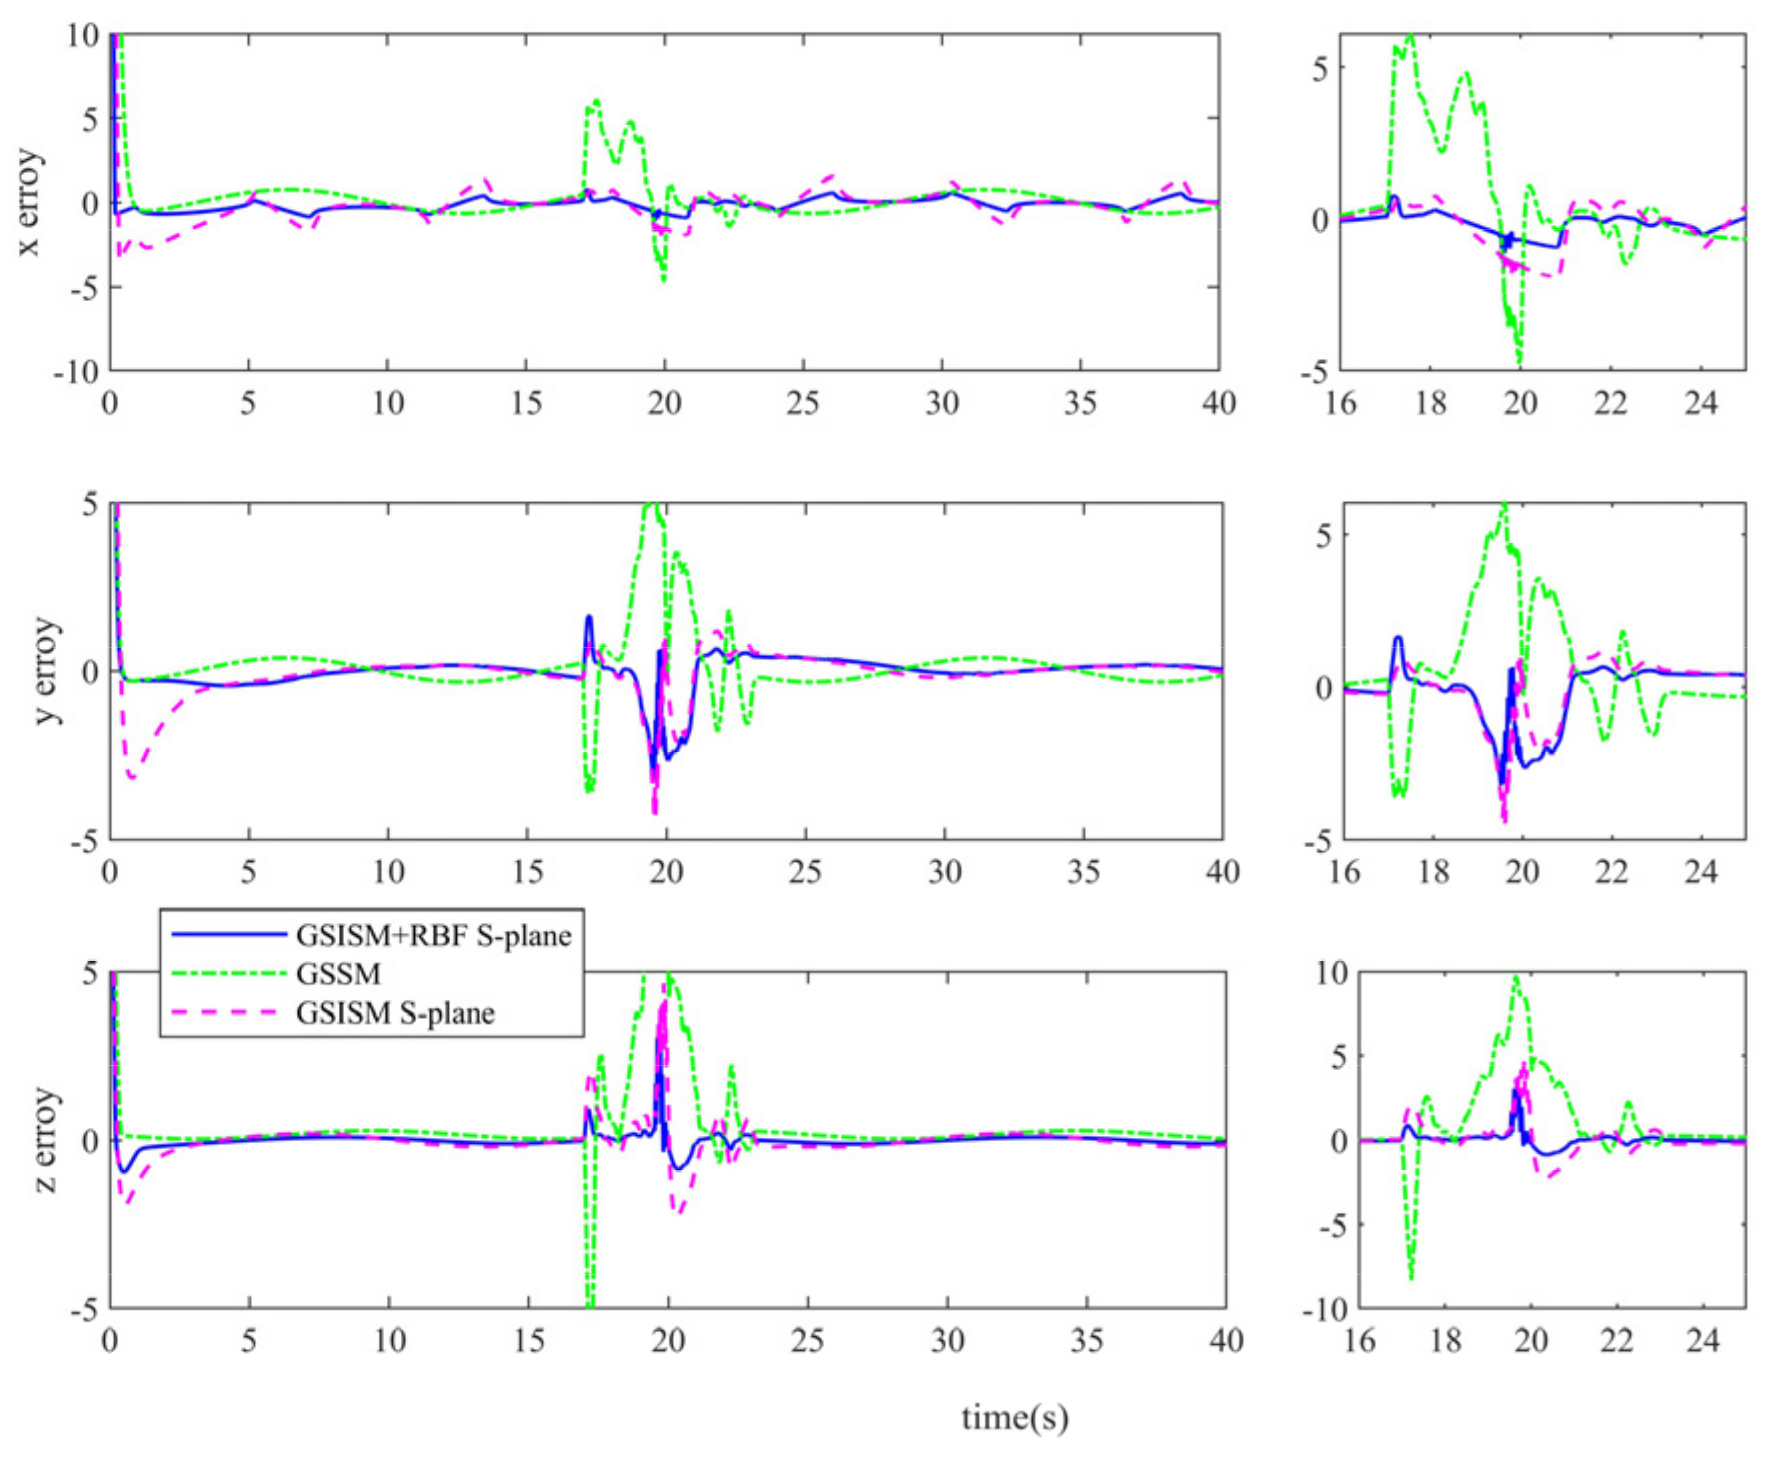
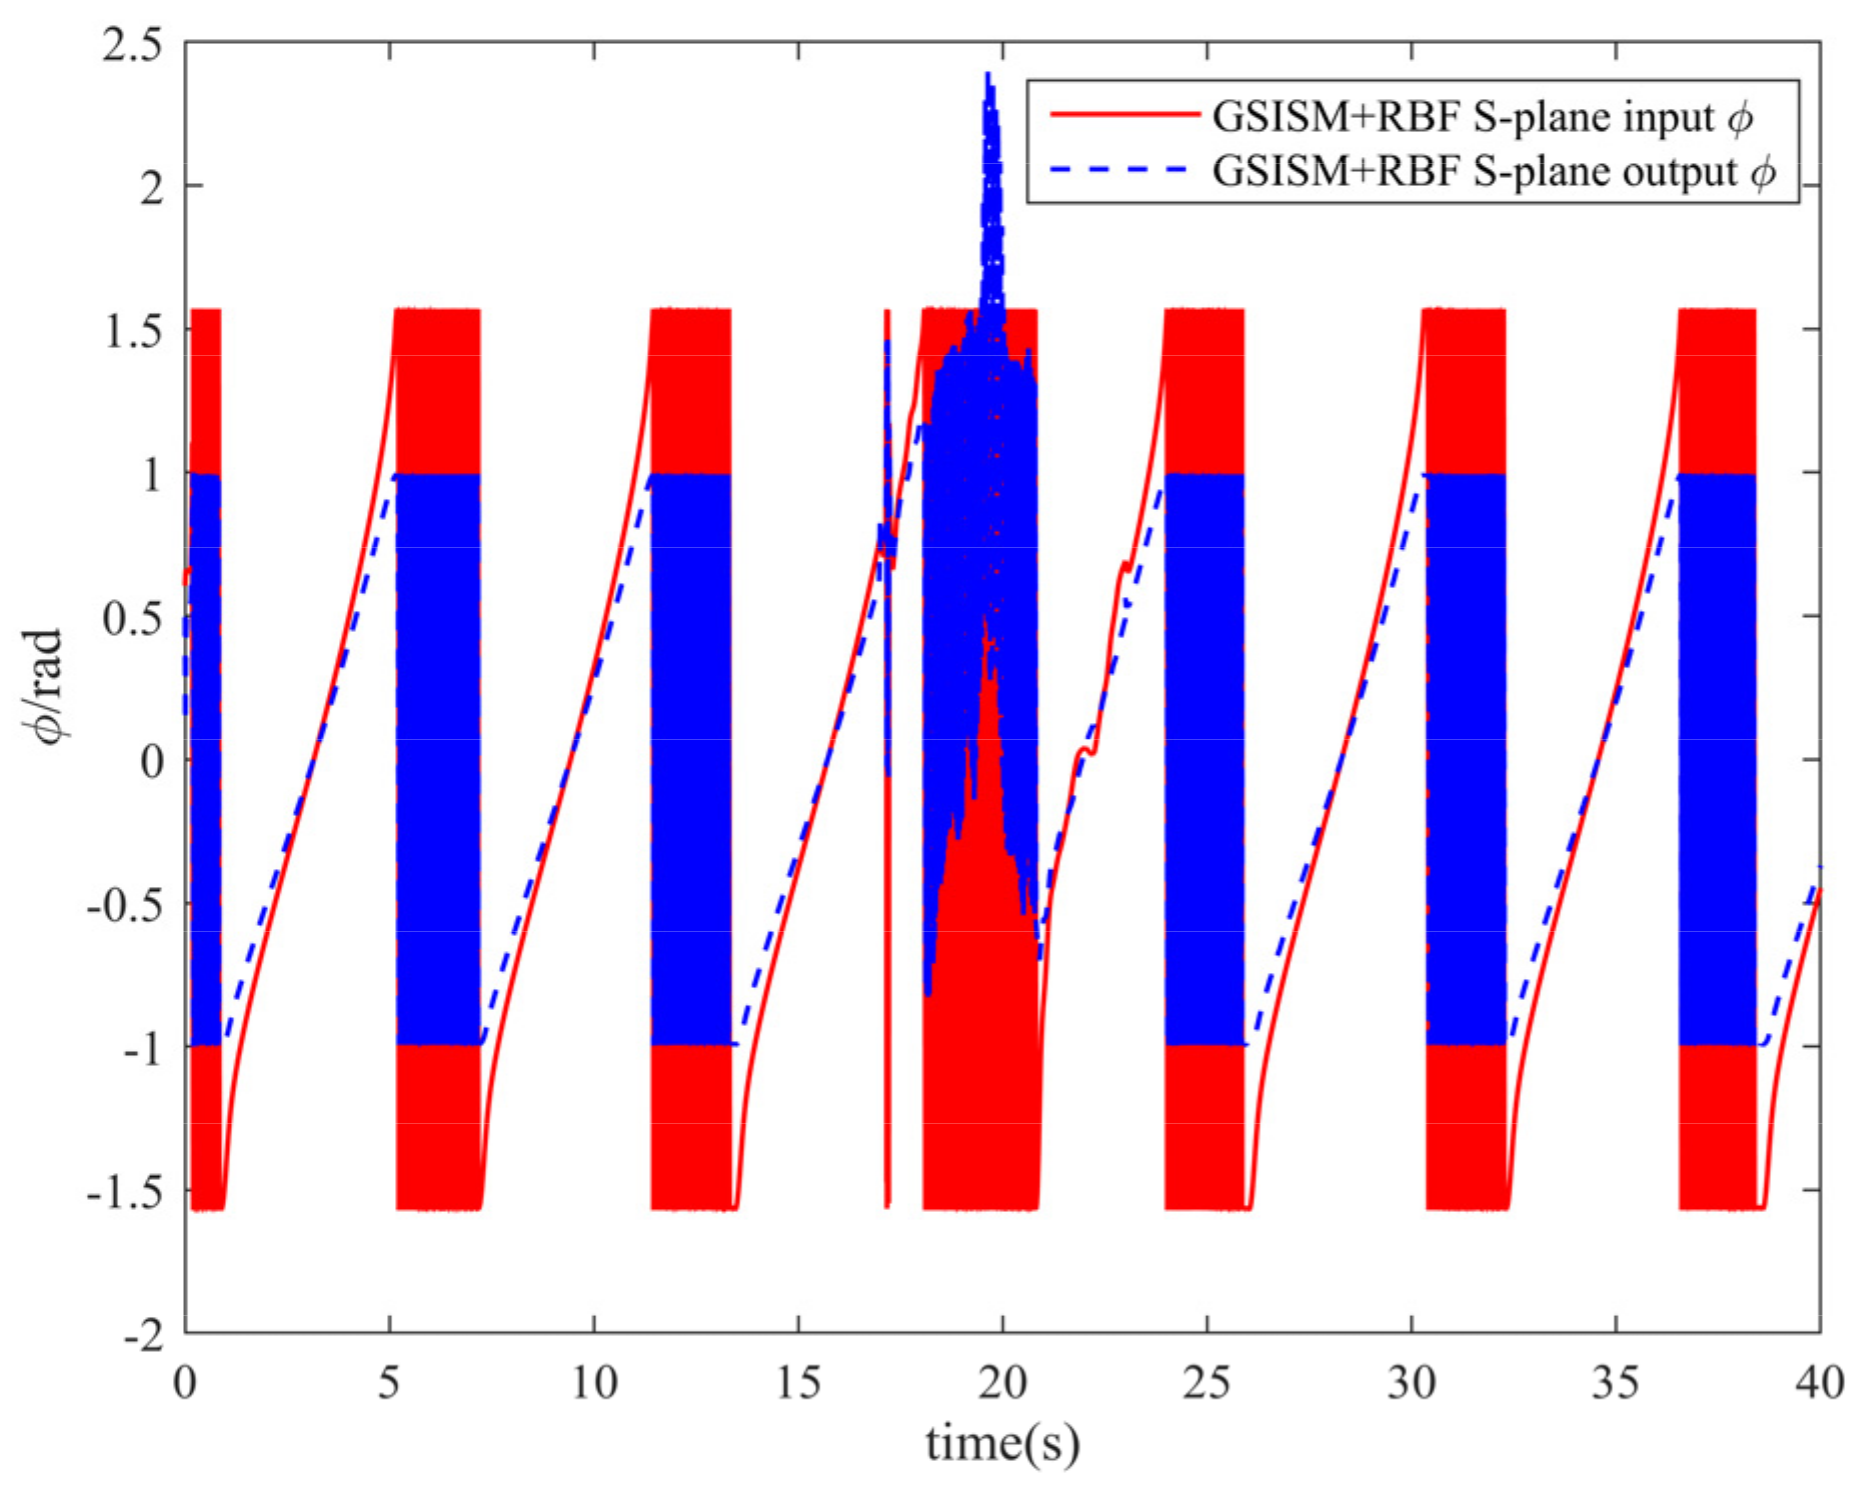
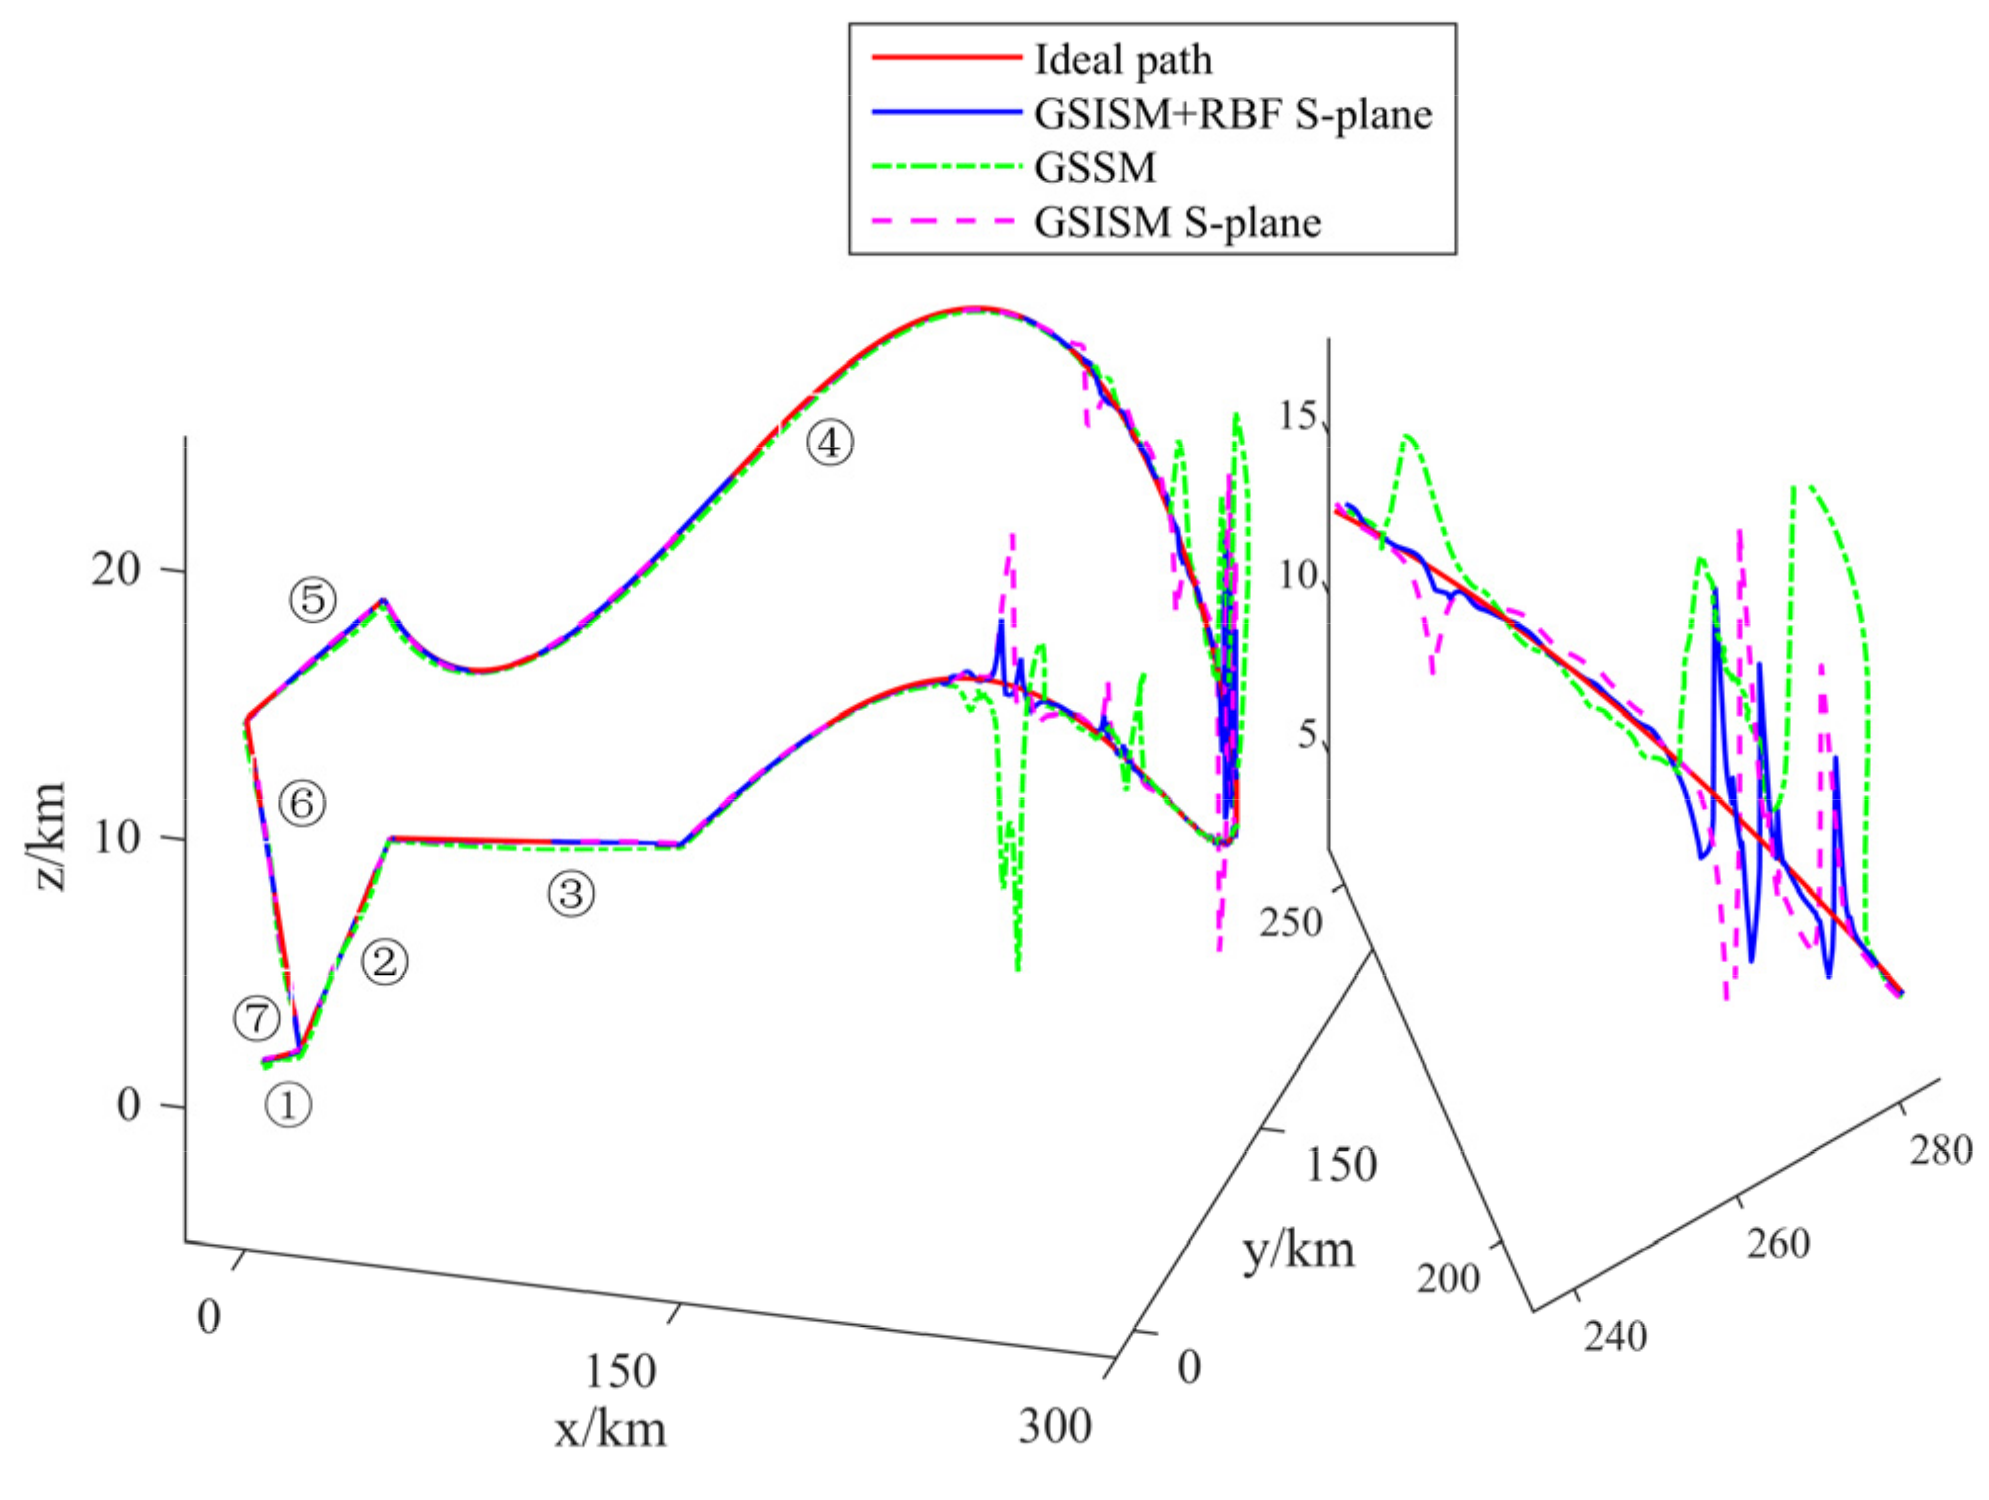
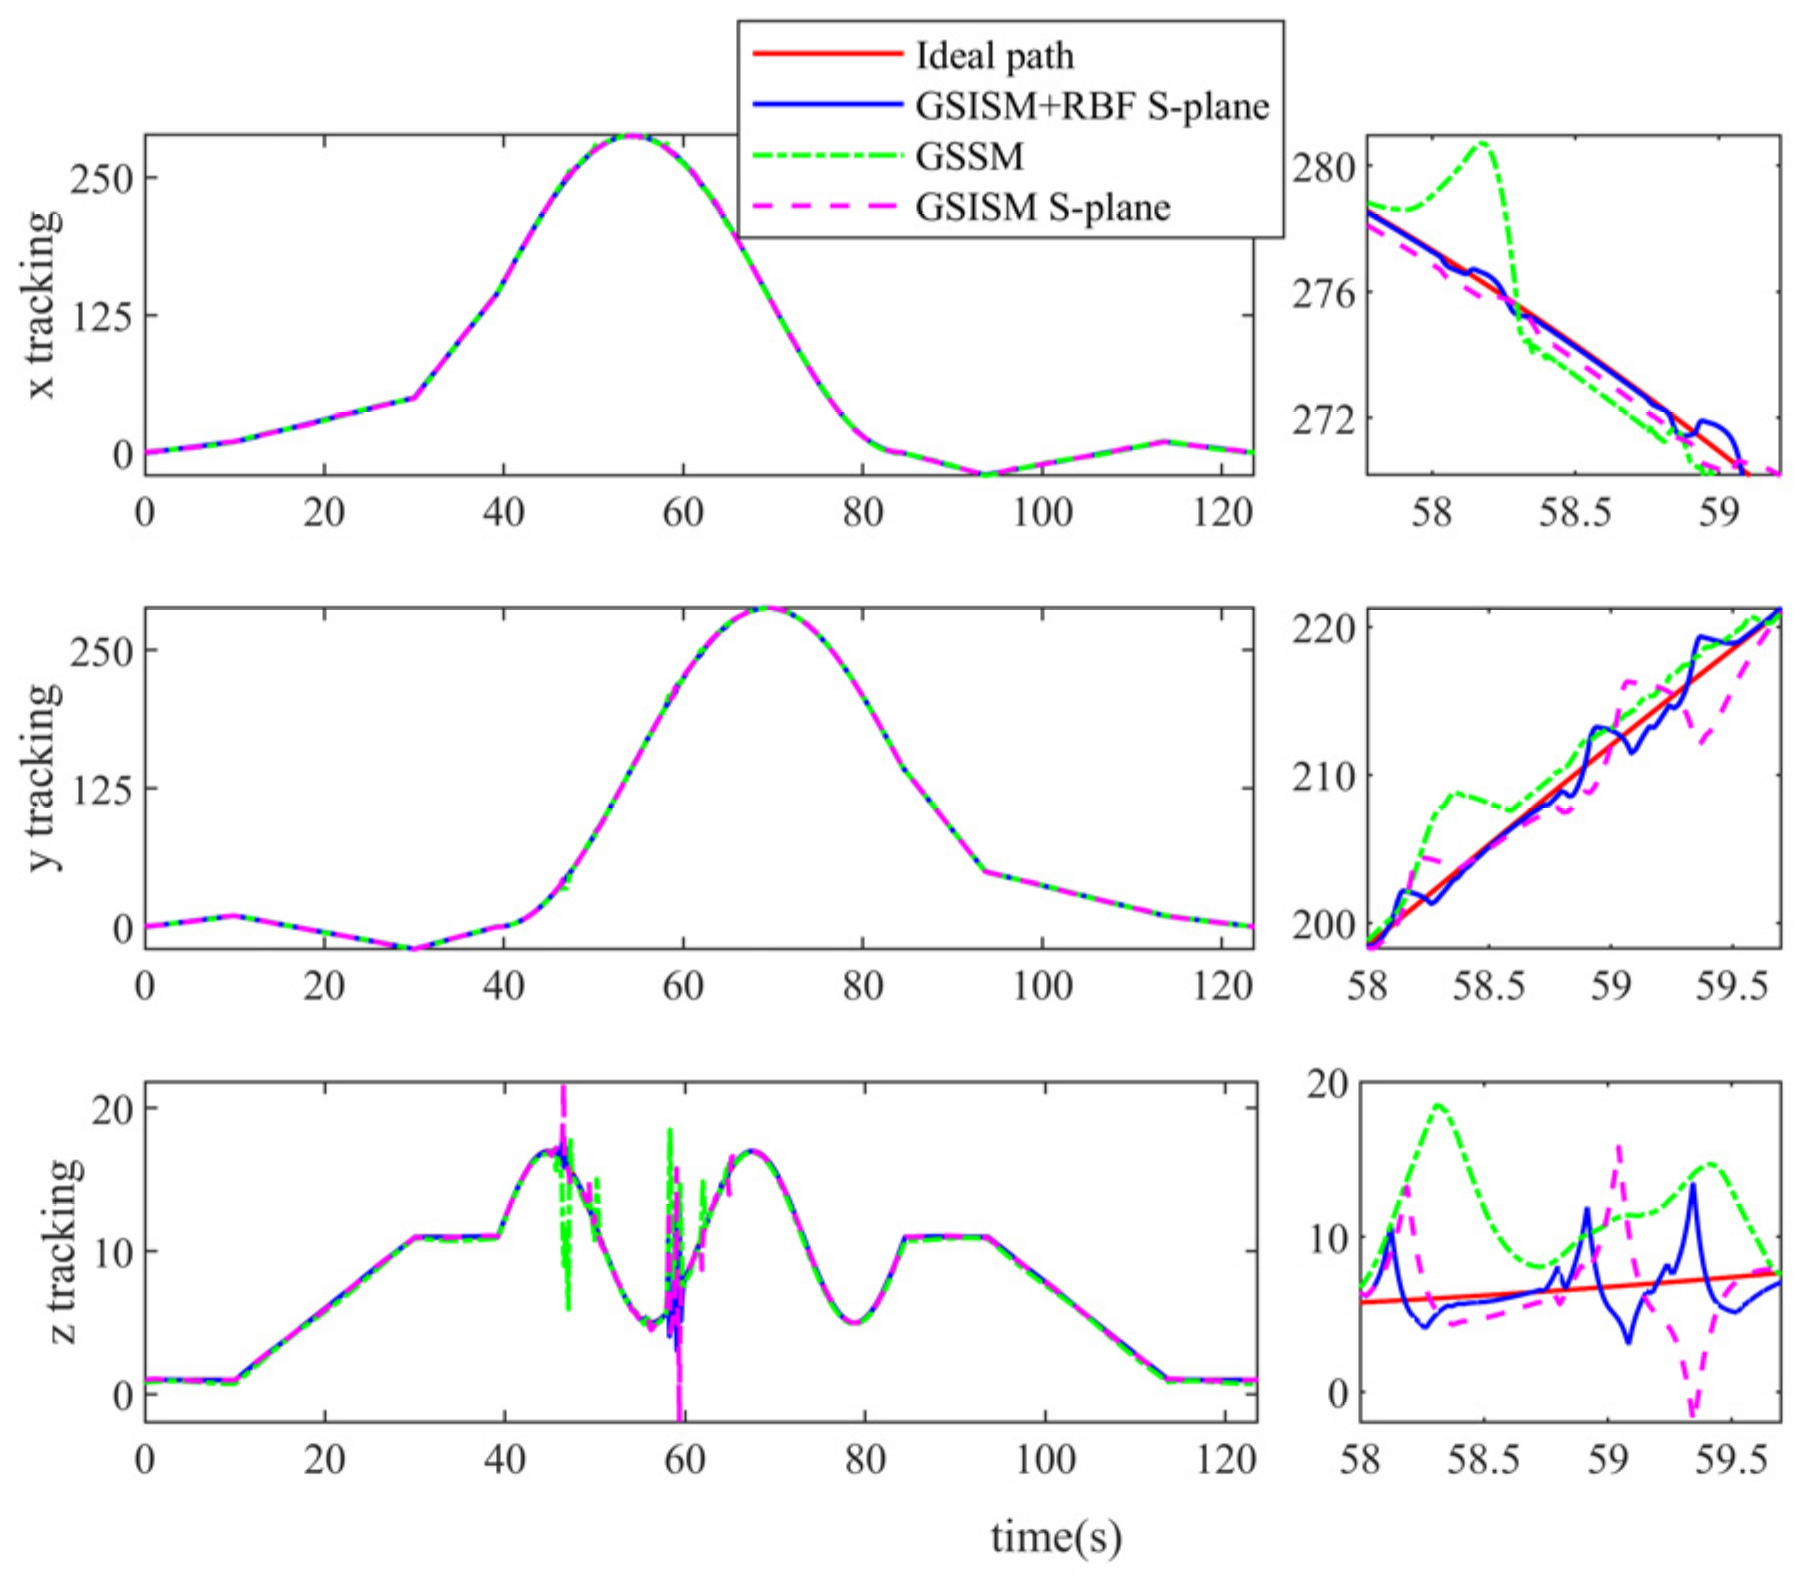
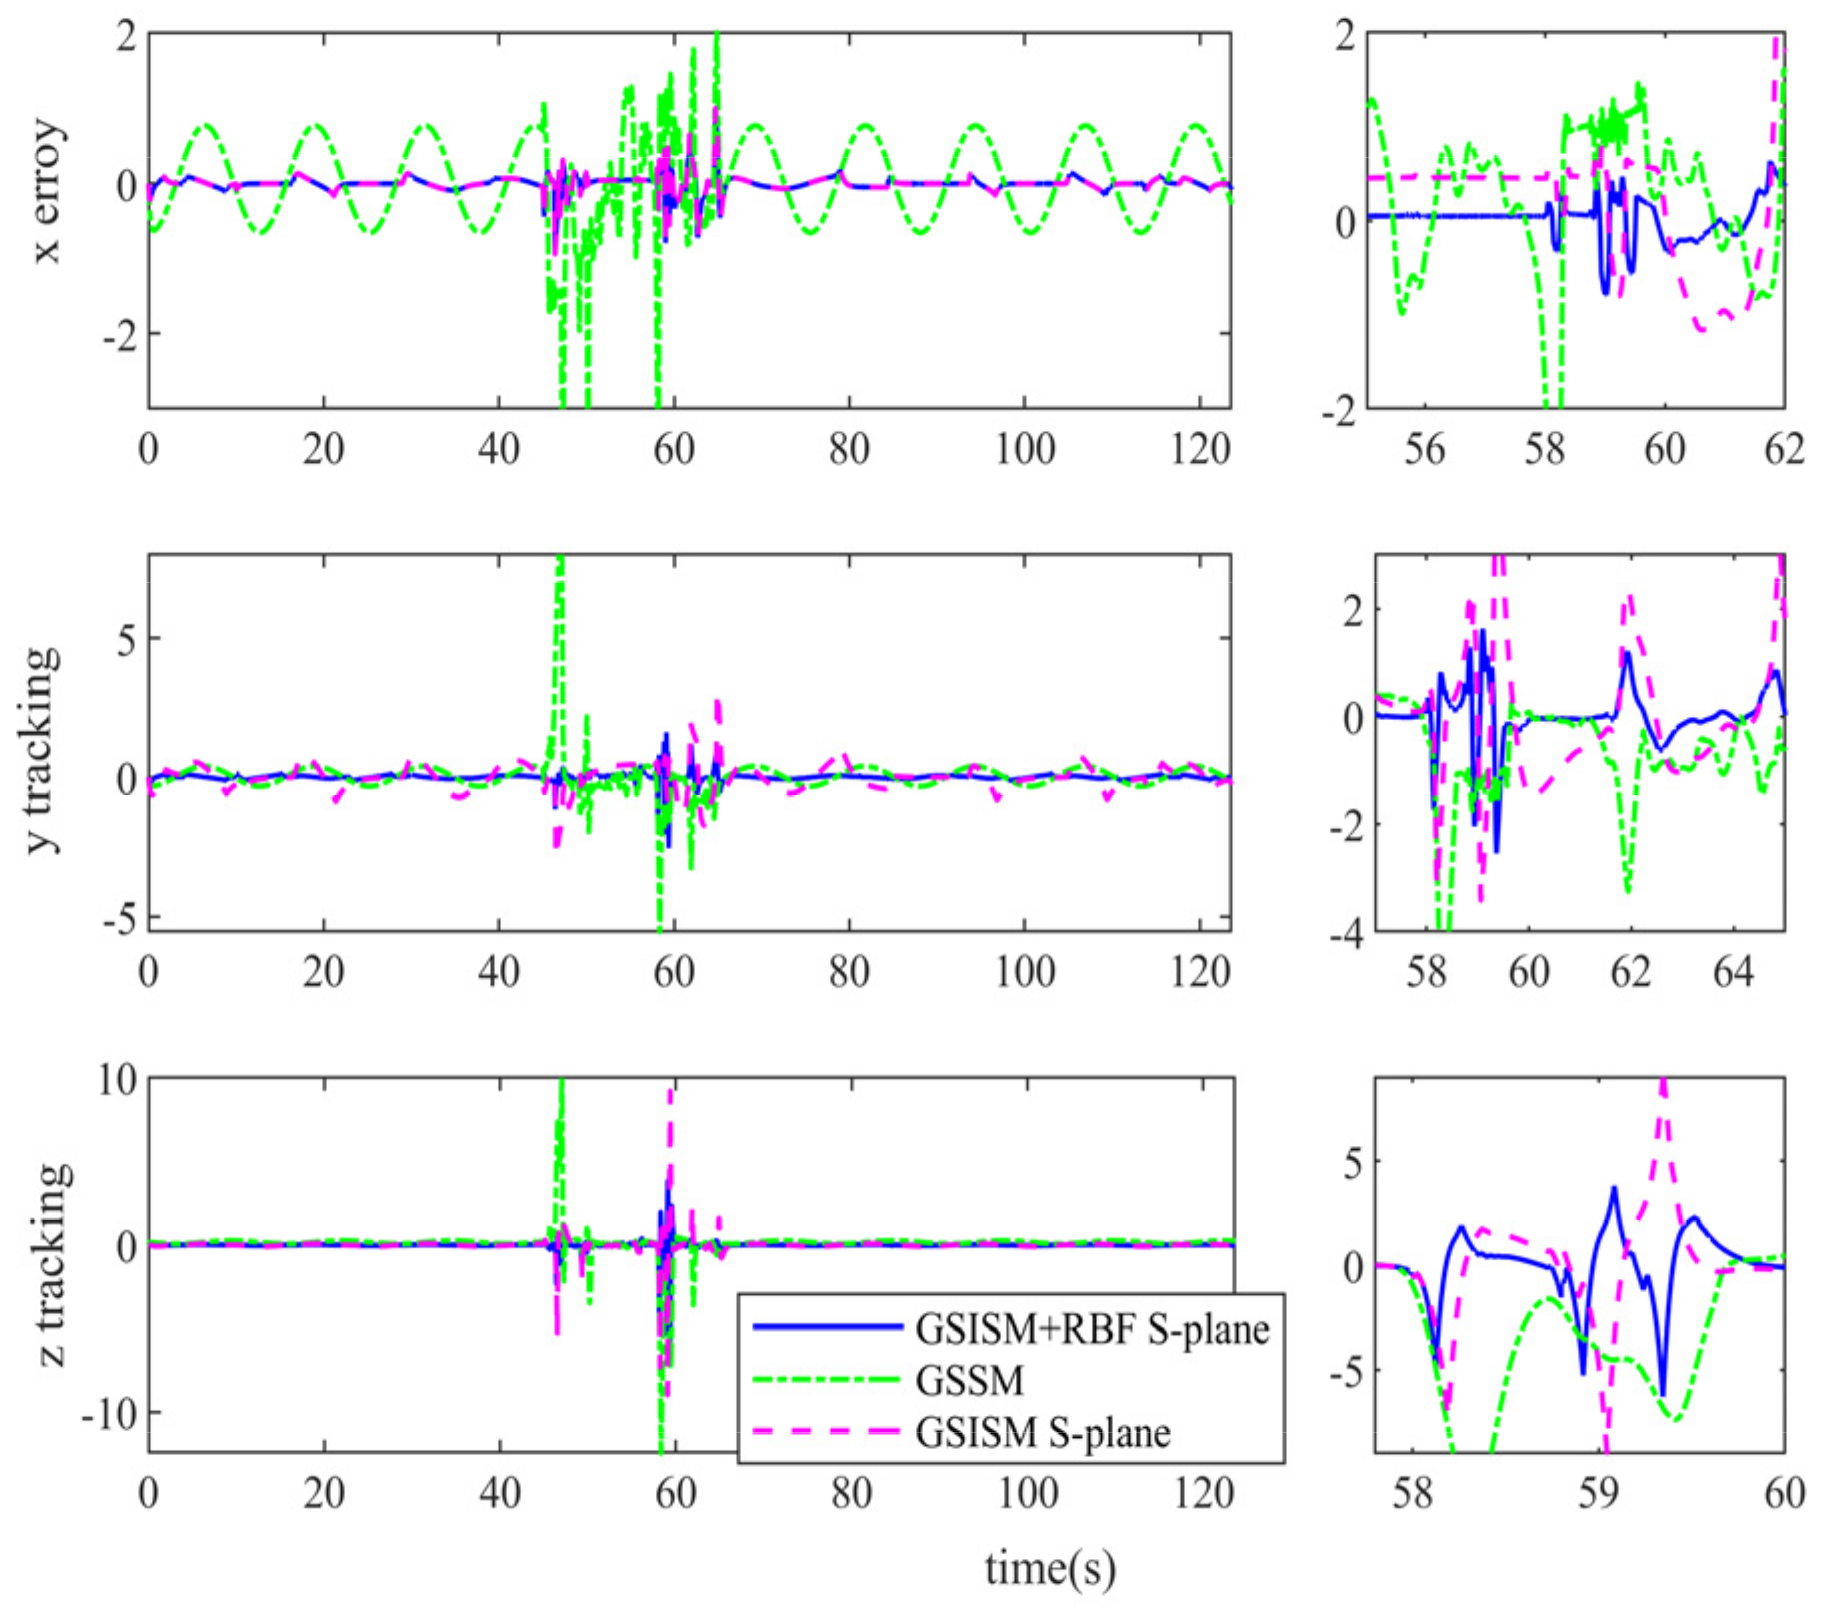
Aiming at the problems of low following accuracy and weak anti-disturbance ability in the three-dimensional path-following control of small fixed-wing Unmanned Aerial Vehicles (UAV), a Globally Stable Integral Sliding Mode Radial Basis Function S-Plane (GSISM+RBF S-Plane) controller is designed. The controller adopts the inner and outer loop mode, the outer loop adopts the Globally Stable Integral Sliding Mode (GSISM) control, and the inner loop adopts the S-Plane control. At the same time, the unknown disturbance in the model is estimated via an RBF neural network. Firstly, the outer loop controller is designed based on the GSISM, and its stability is proved using the Lyapunov theory. Then, the S-Plane controller is designed for the instruction signal of the inner loop. Considering the complexity of the derivation in the S-Plane controller, a second-order differentiator is introduced. Finally, considering the problem of external wind disturbance, the controller is modeled, studied, and processed in order to better reflect the impact of real external wind on UAV path following. Finally, the Globally Stable Sliding Mode (GSSM) control and Globally Stable Integral Sliding Mode S-Plane (GSISM S-Plane) control are used for a comparative experiment. The simulation results show that the designed GSISM+RBF S-Plane controller can accurately track the ideal path compared with the GSSM and GSISM S-Plane controller, and it has good control performance and anti-disturbance performance.
Keywords: fixed-wing UAV; path following; GSISM+RBF S-Plane controller; wind disturbances fixed-wing UAV; path following; GSISM+RBF S-Plane controller; wind disturbances