
A Review of Magnetically Controlled Continuum Robots: Principles, Classification, and Applications


 ,
Abstract
1. Introduction
2. Principles and System Setup
2.1. Principles of Magnetically Controlled Continuum Robots
2.1.1. Principles of Magnetic Actuation
2.1.2. Modeling of Continuum Robots
2.1.3. Principles of Magnetic Field Generation
2.2. Systems of Magnetic Manipulation
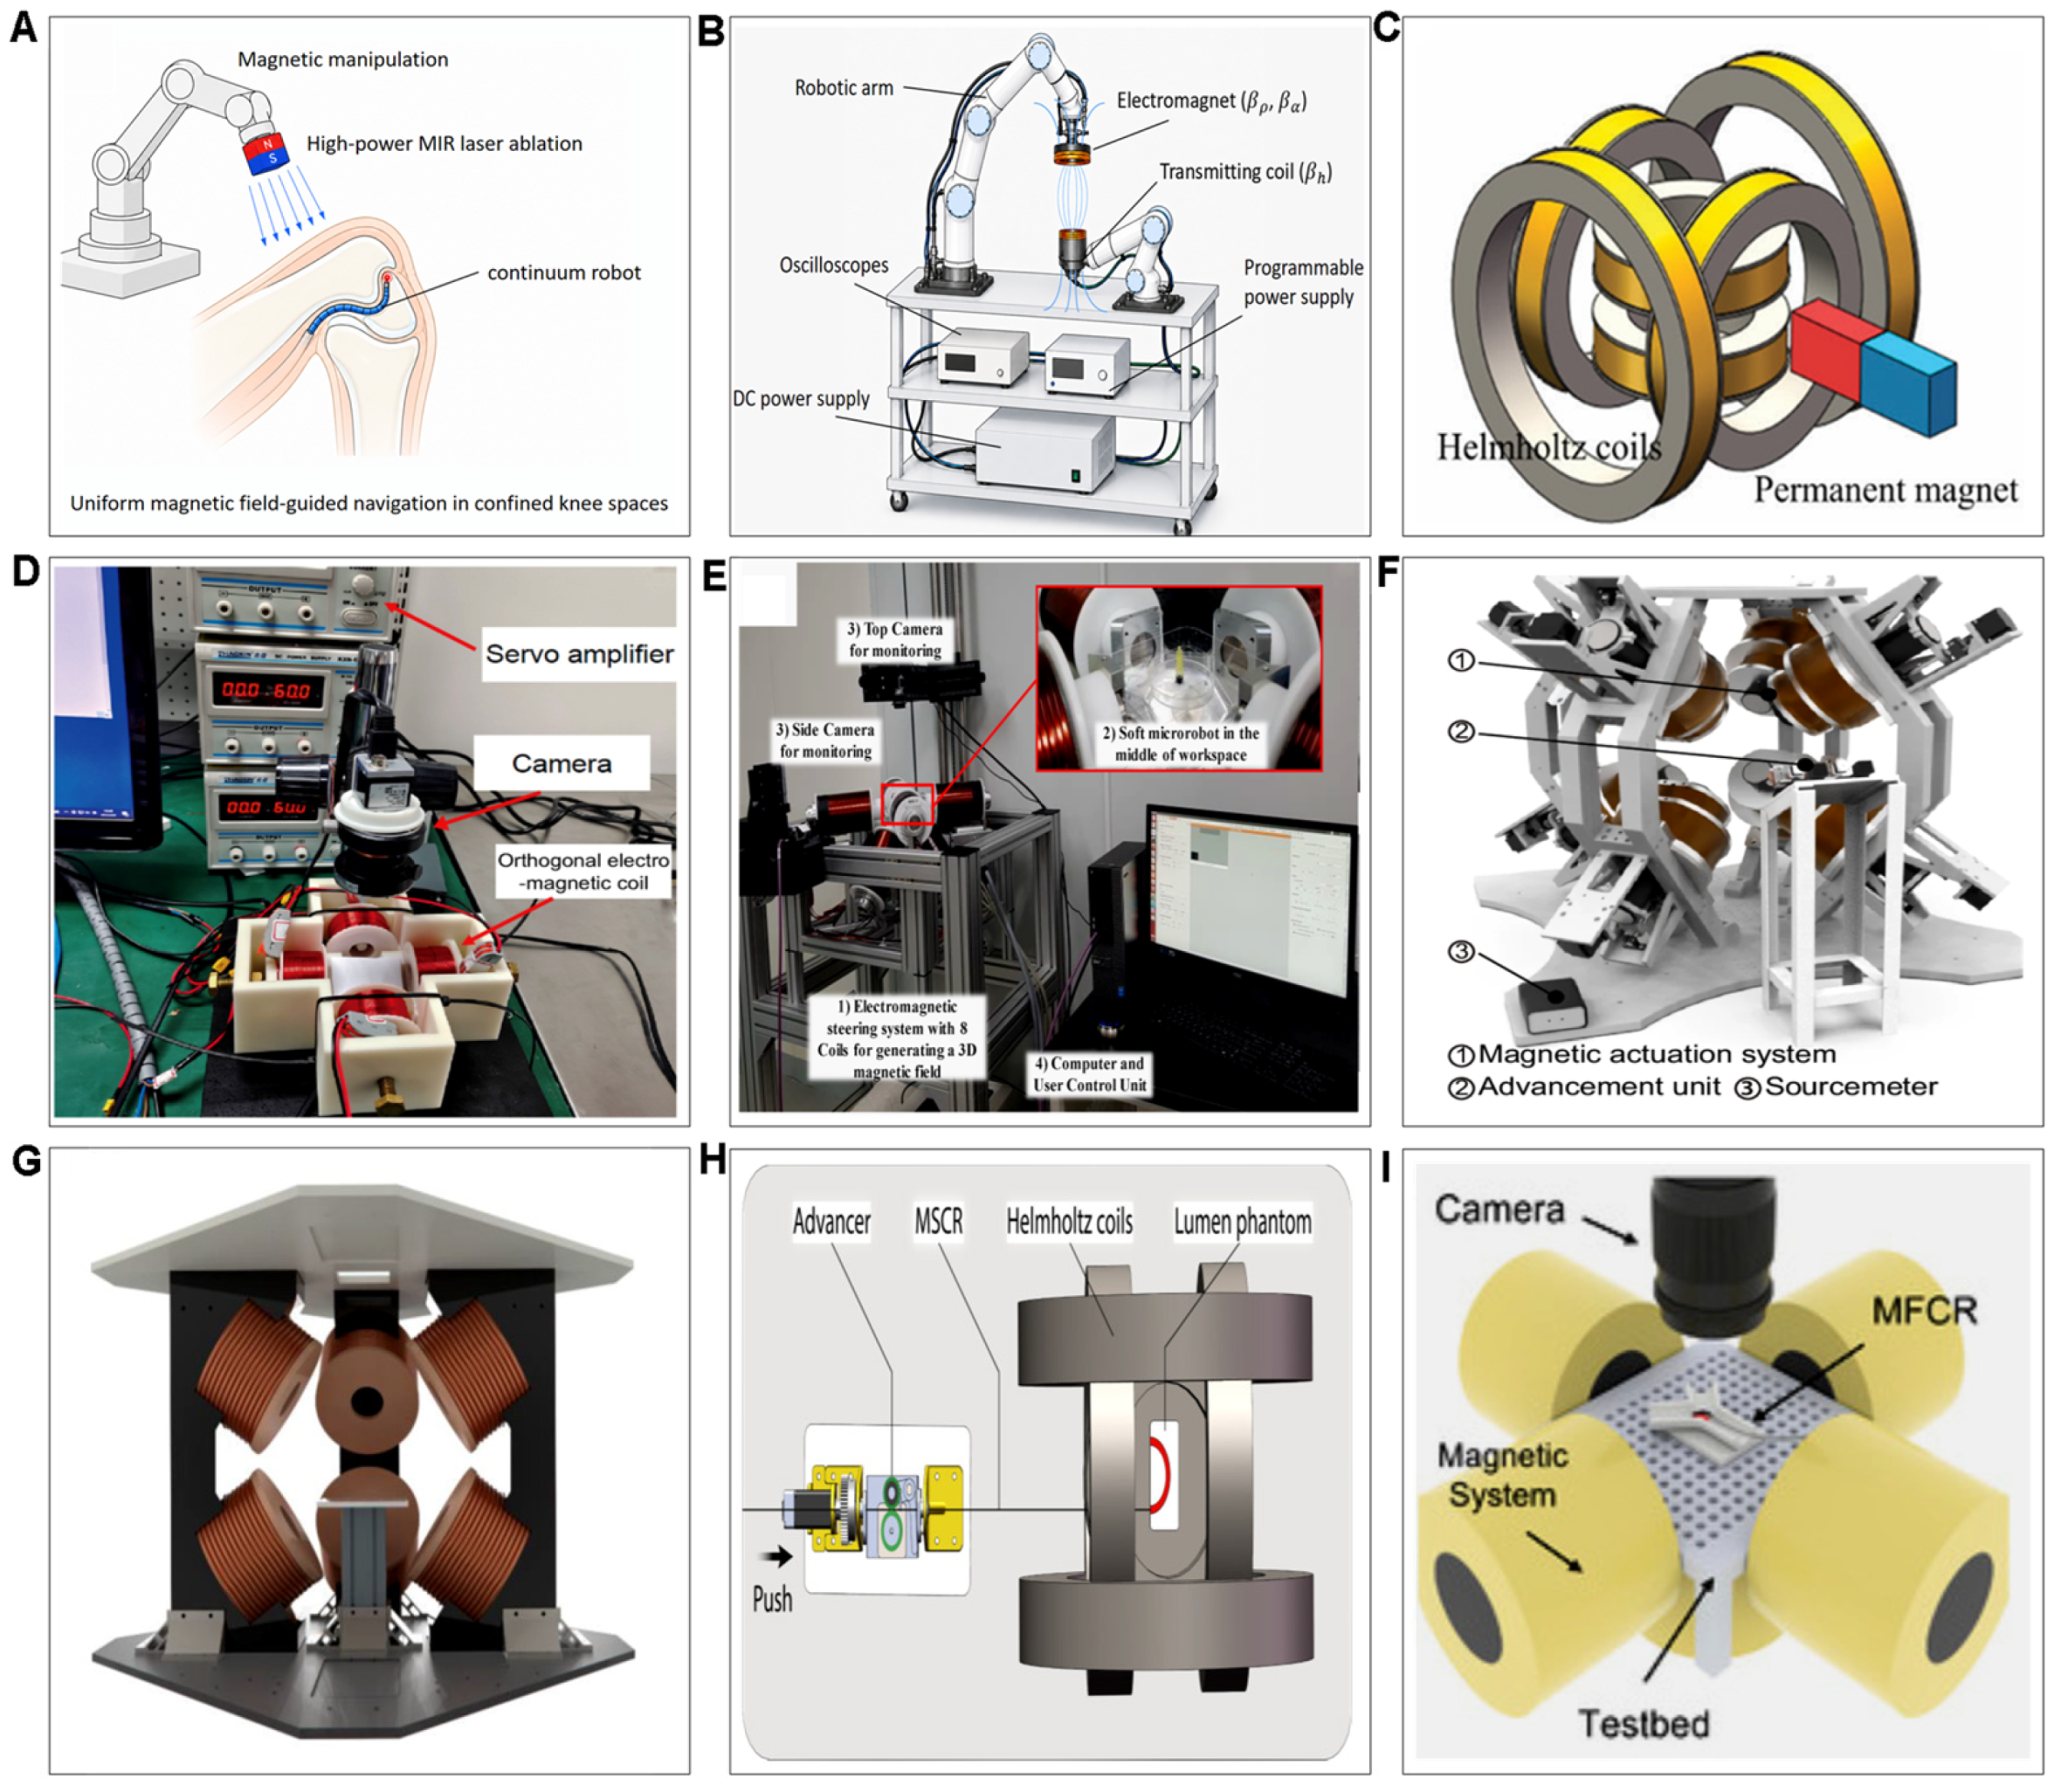
2.2.1. Permanent Magnets

2.2.2. Magnetic Coils
2.2.3. Hybrid Platforms
2.3. Evolution of Motion Control Strategies
3. Classification of Magnetically Controlled Continuum Robots
3.1. Guiding/Steering Continuum Robot
3.1.1. Magnetic Guidewires
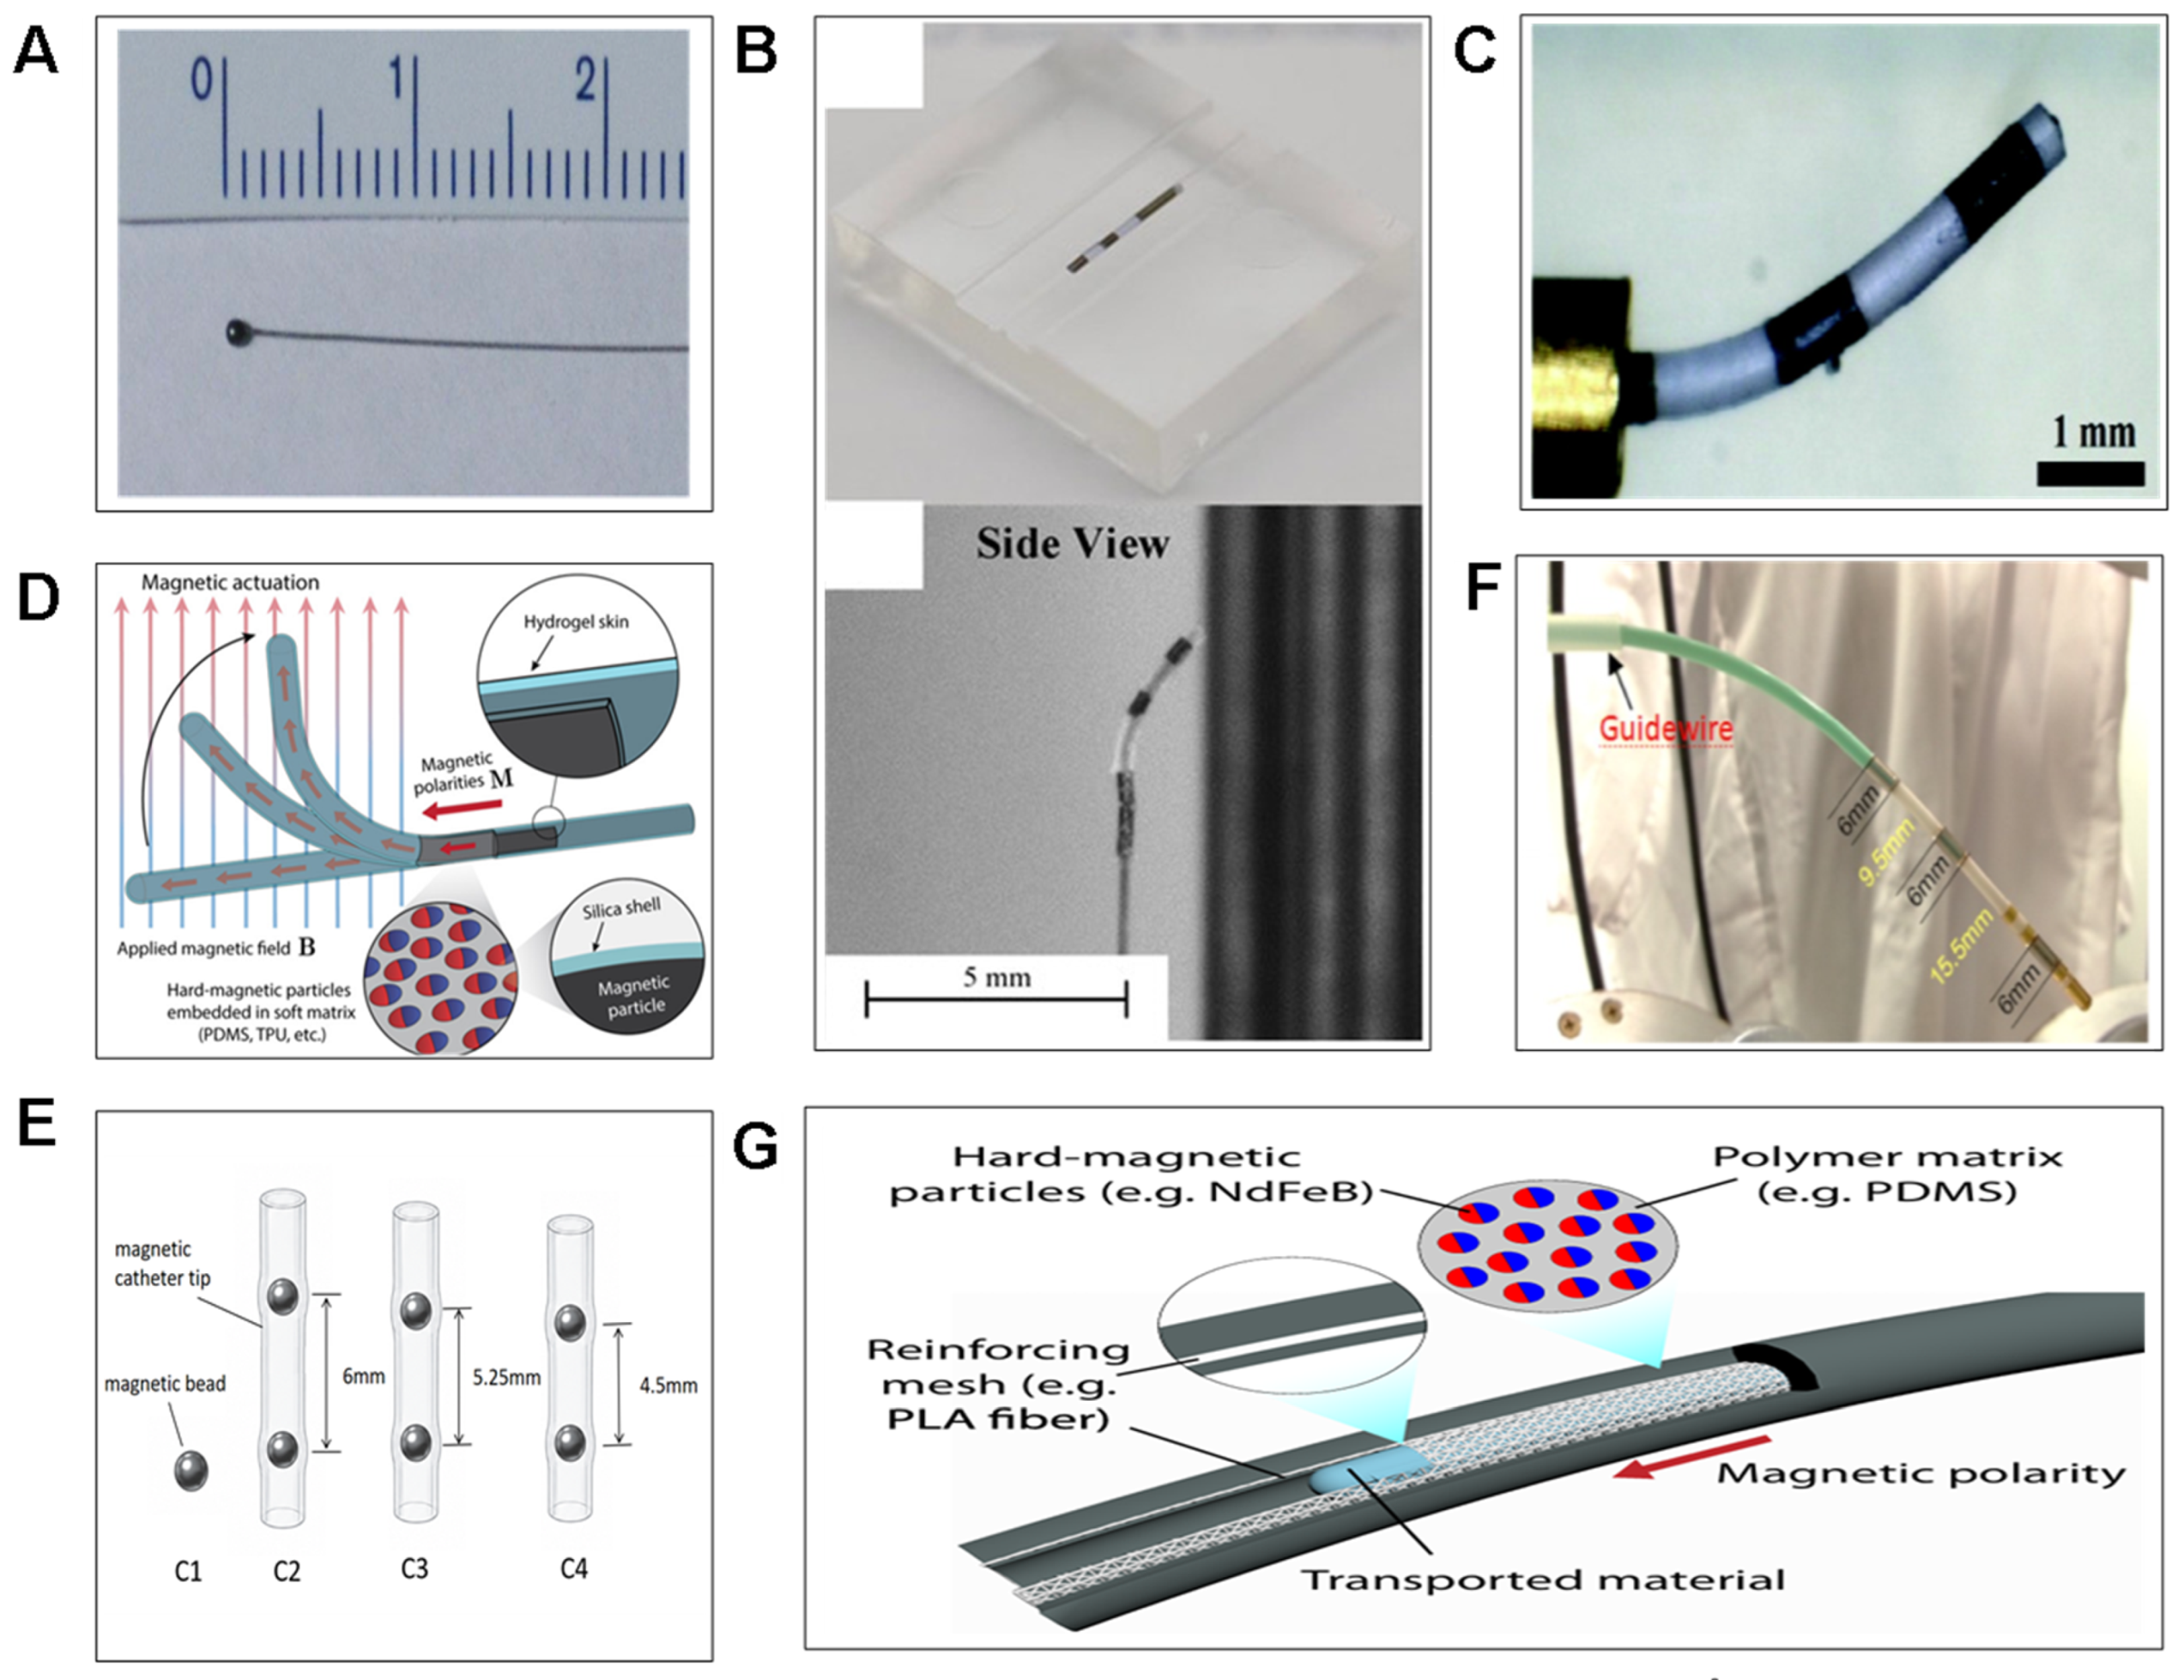
3.1.2. Magnetic Conduits
3.2. Variable Stiffness Continuum Robot
3.2.1. Variable Stiffness Based on Material Properties
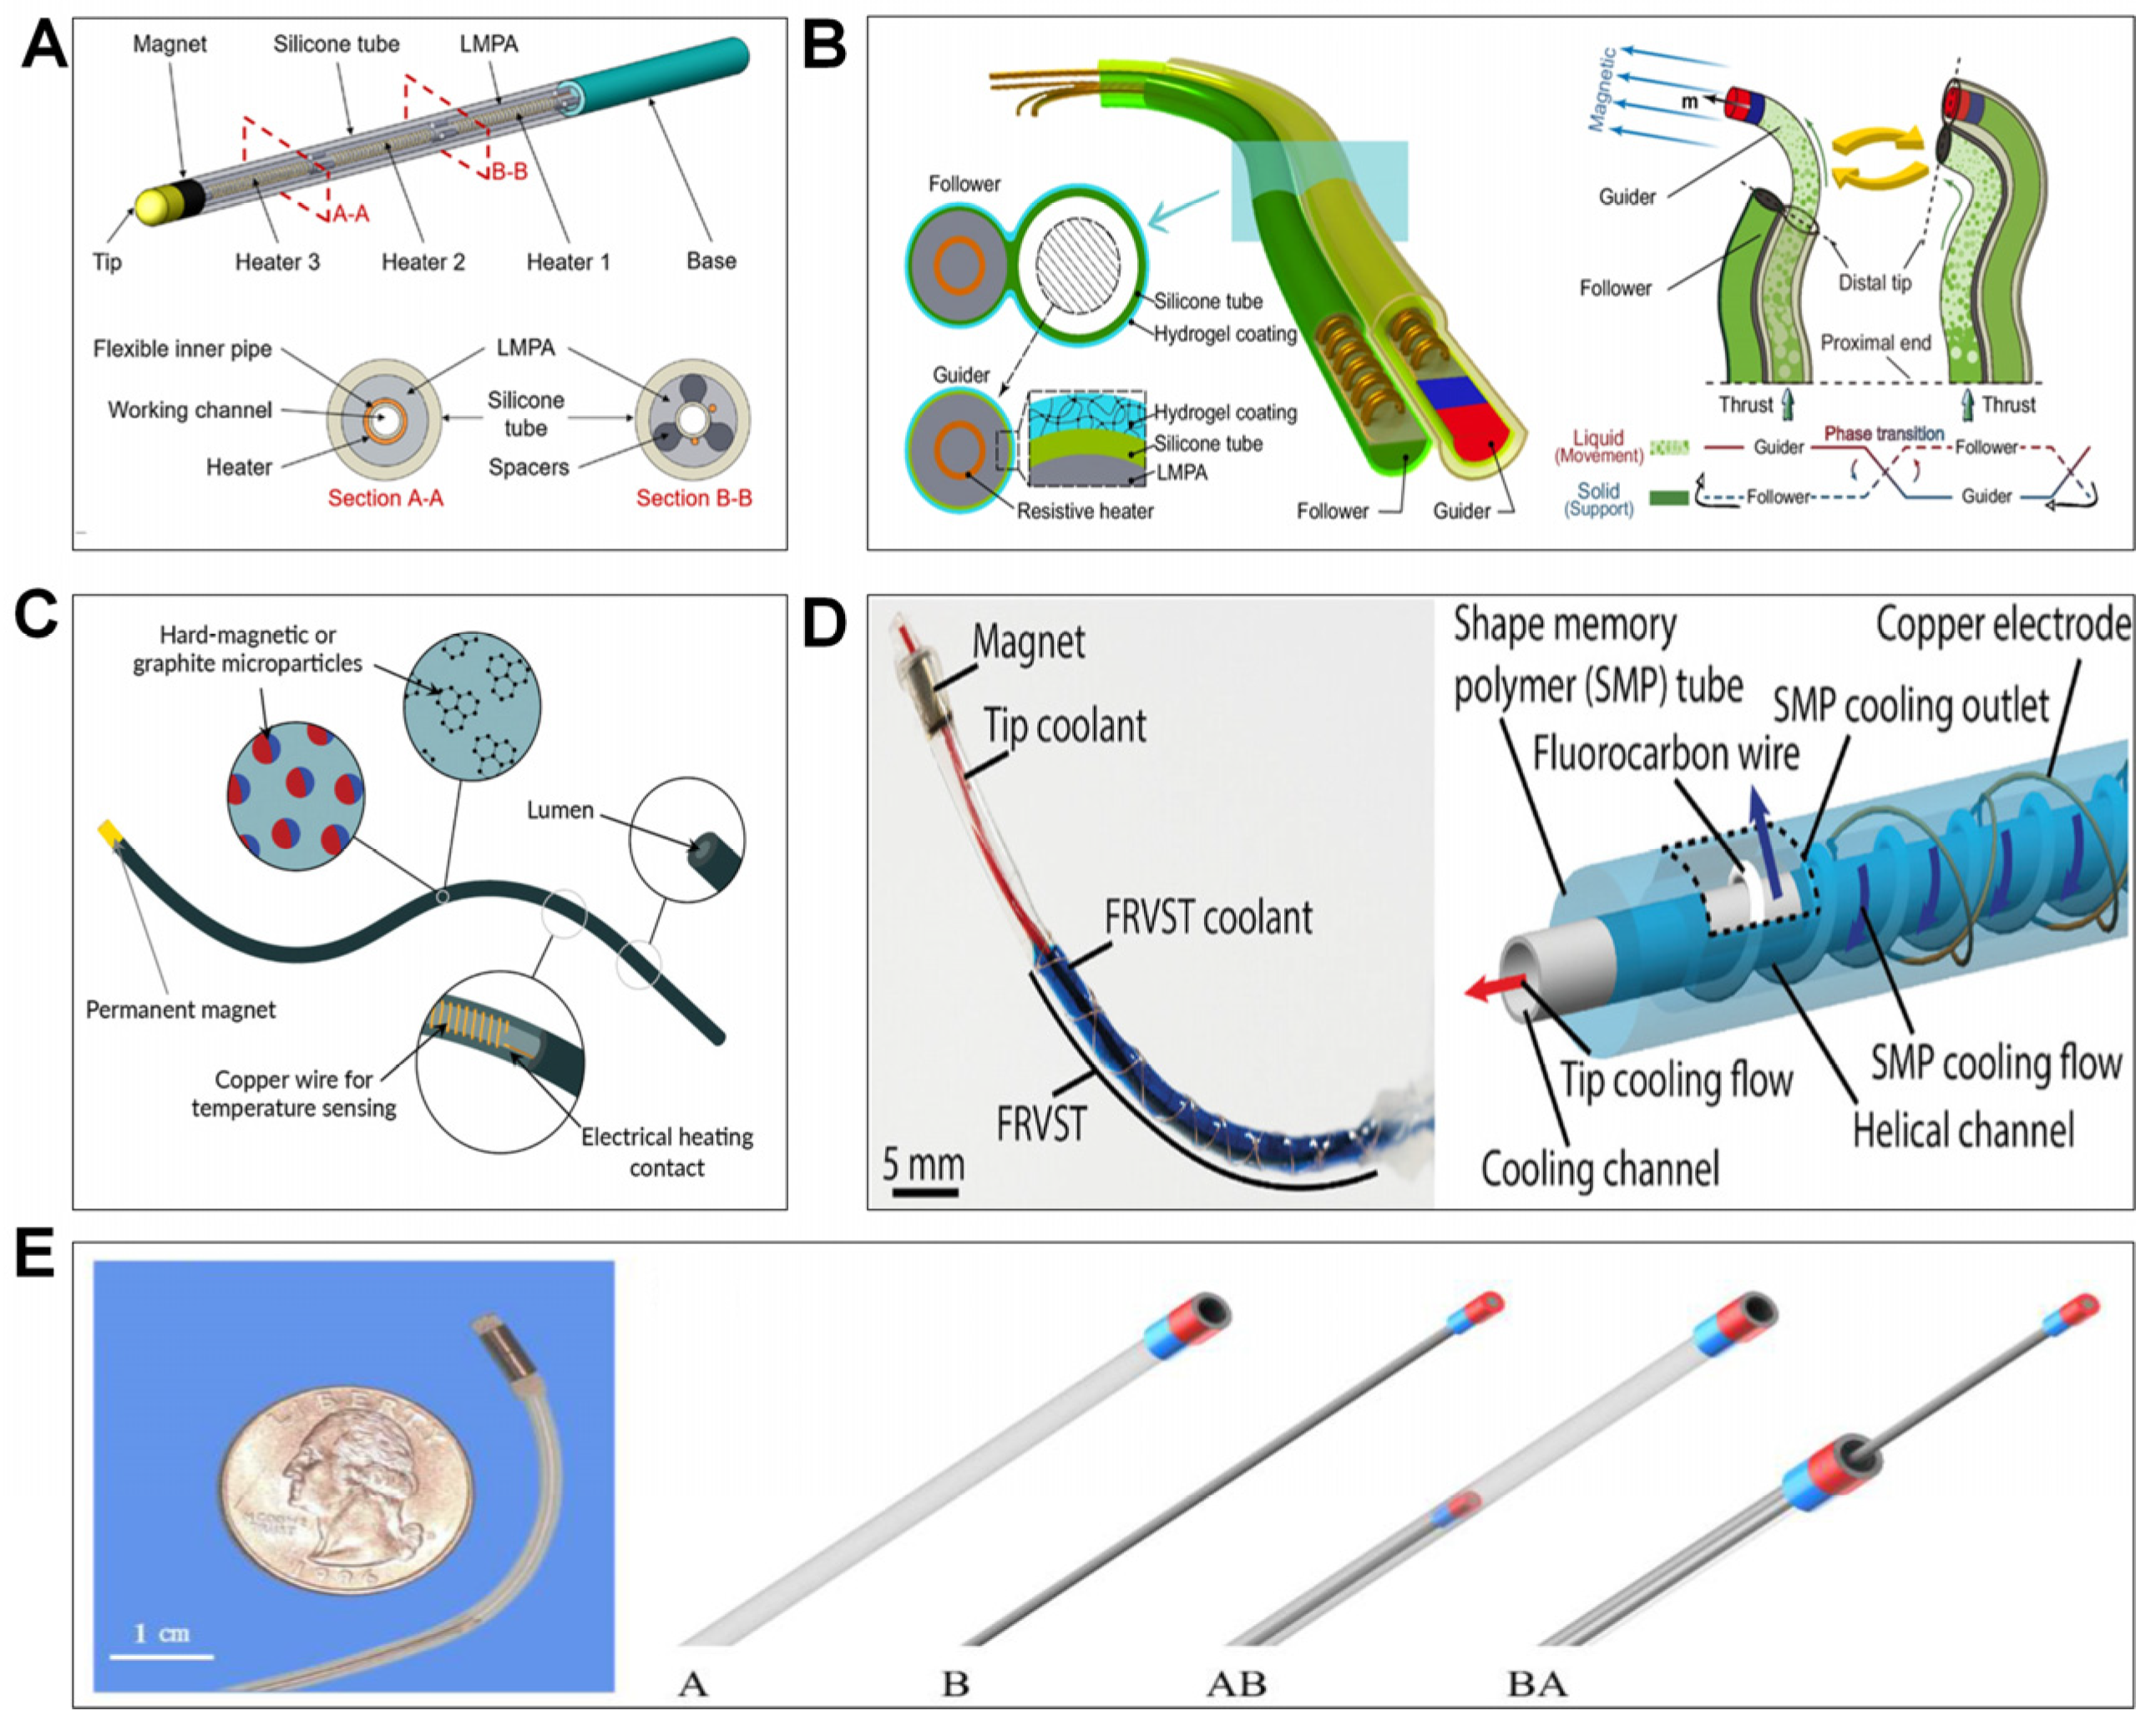
3.2.2. Variable Stiffness Based on Structural Design
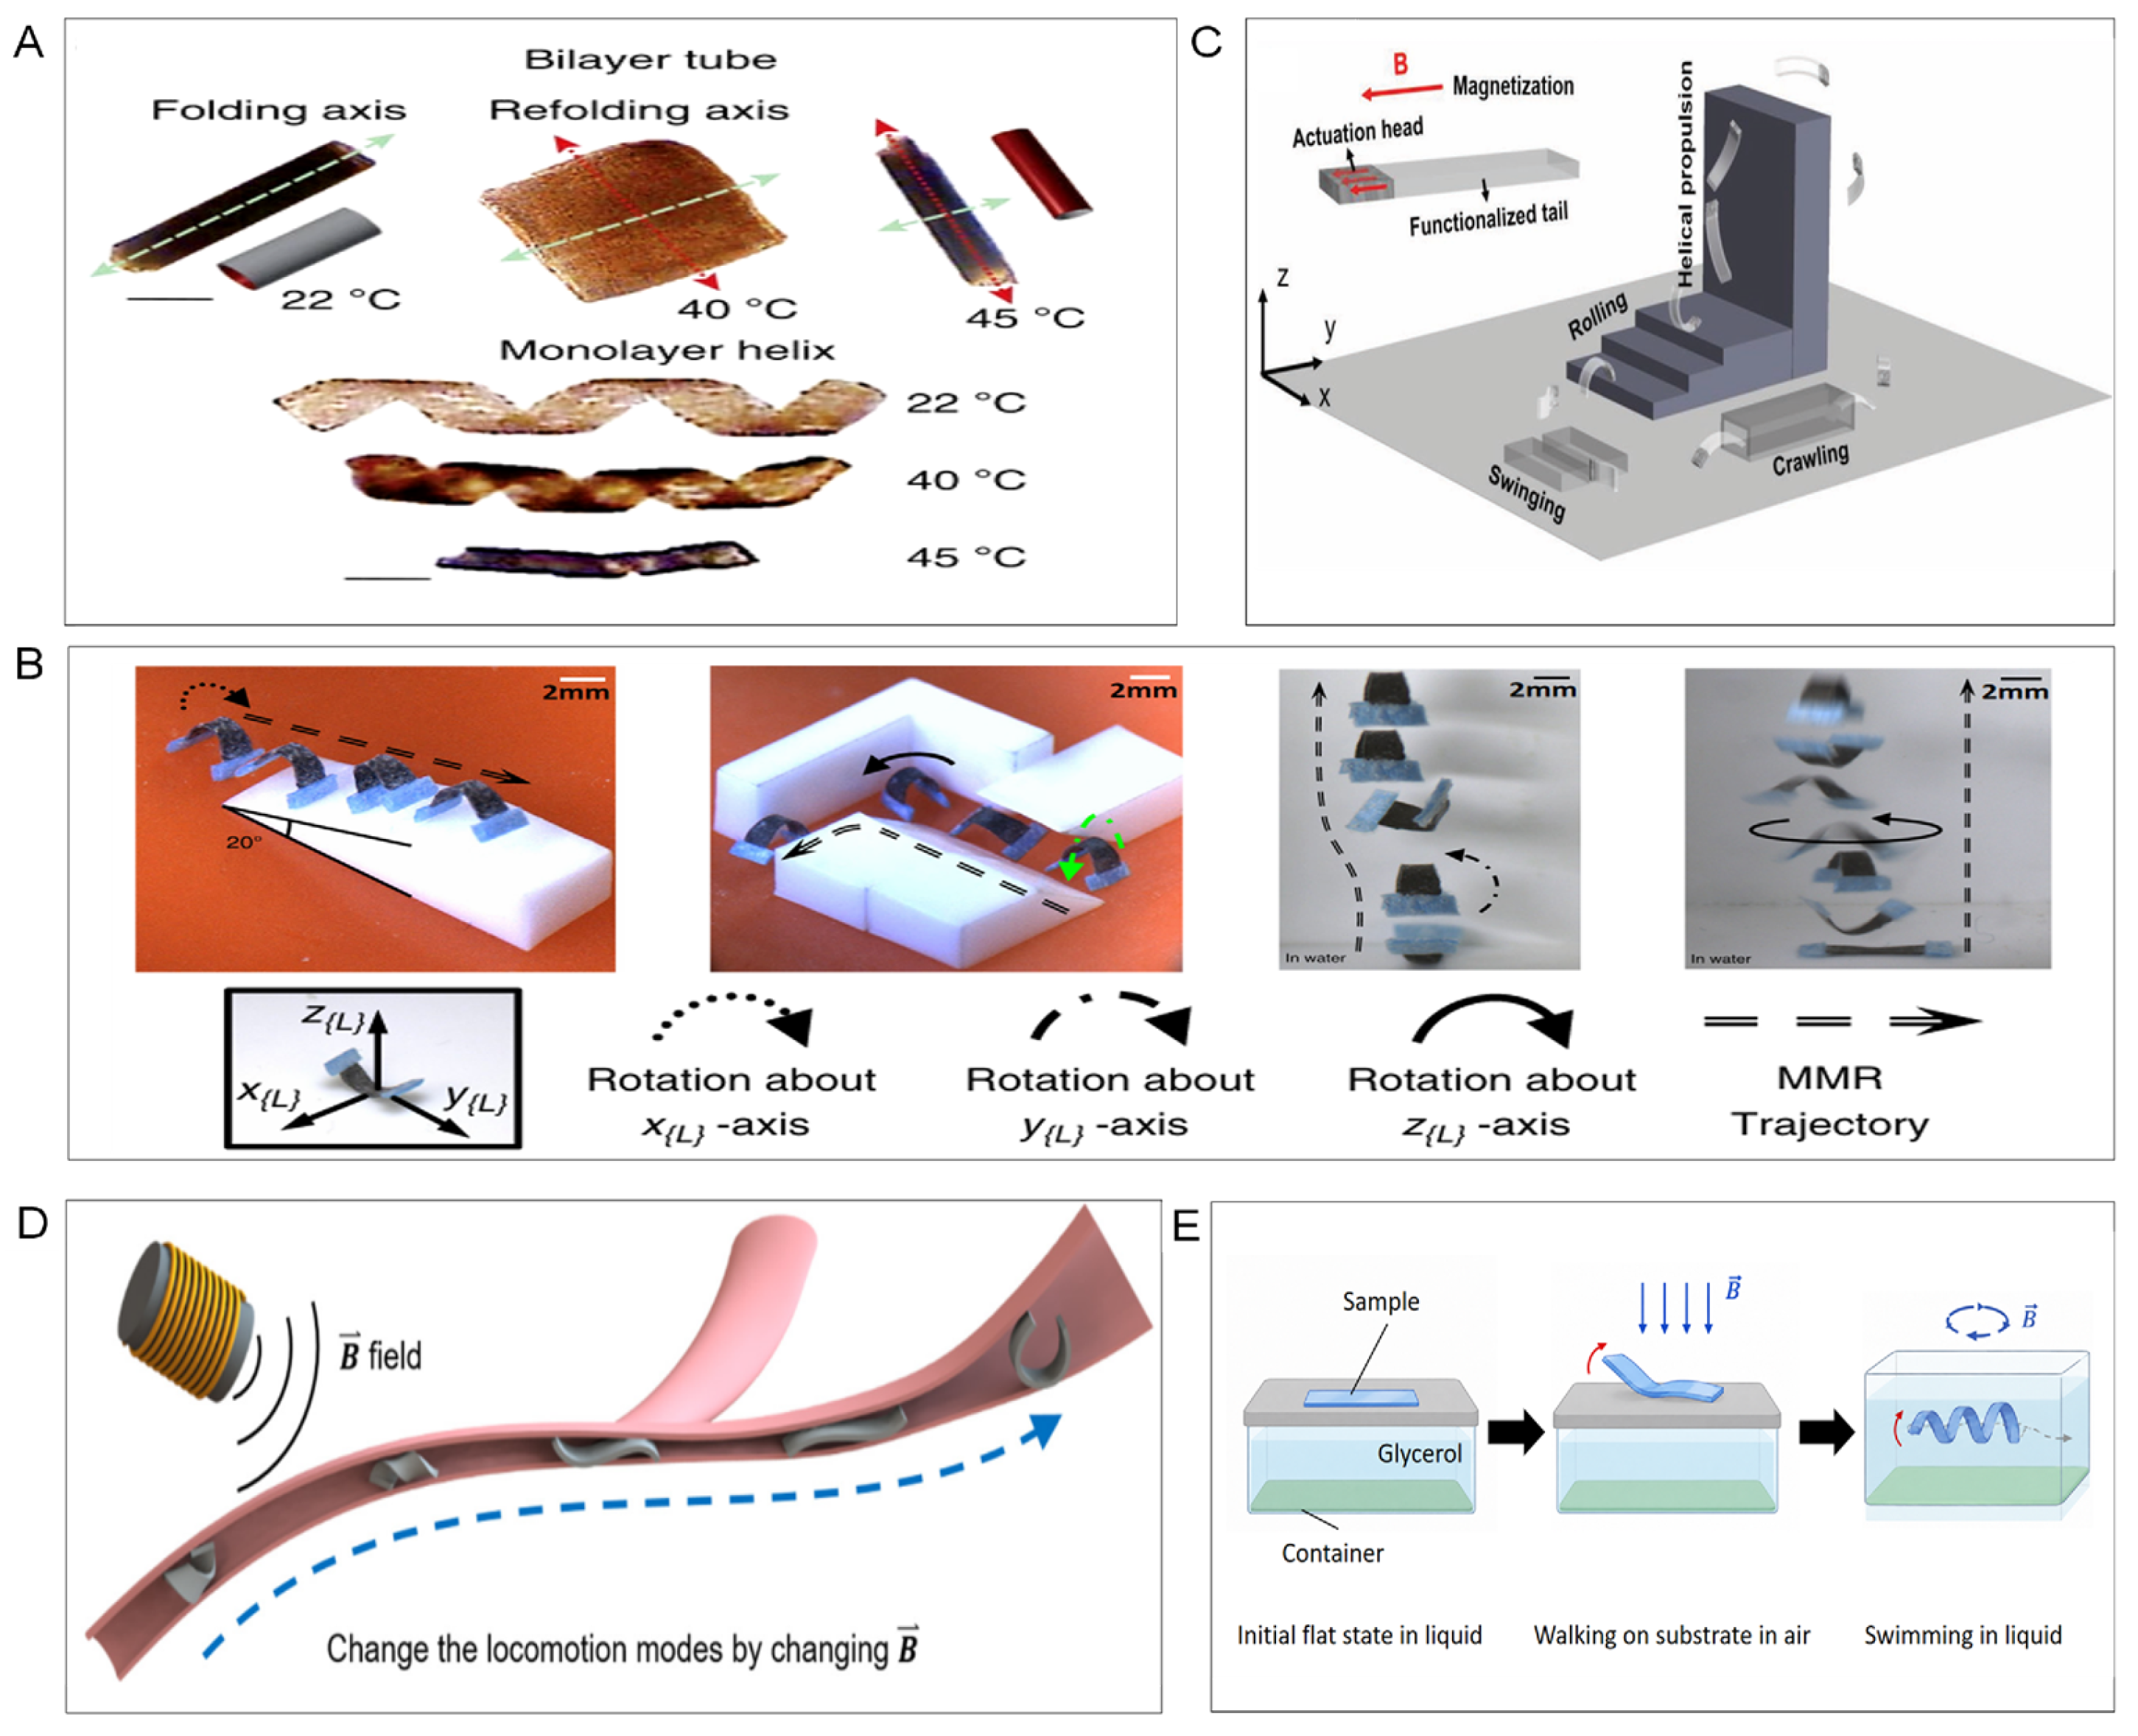
3.3. Multimodal Motion Continuum Robot
3.3.1. Motion Pattern Reconstruction

3.3.2. Based on Structural Morphology Transformation
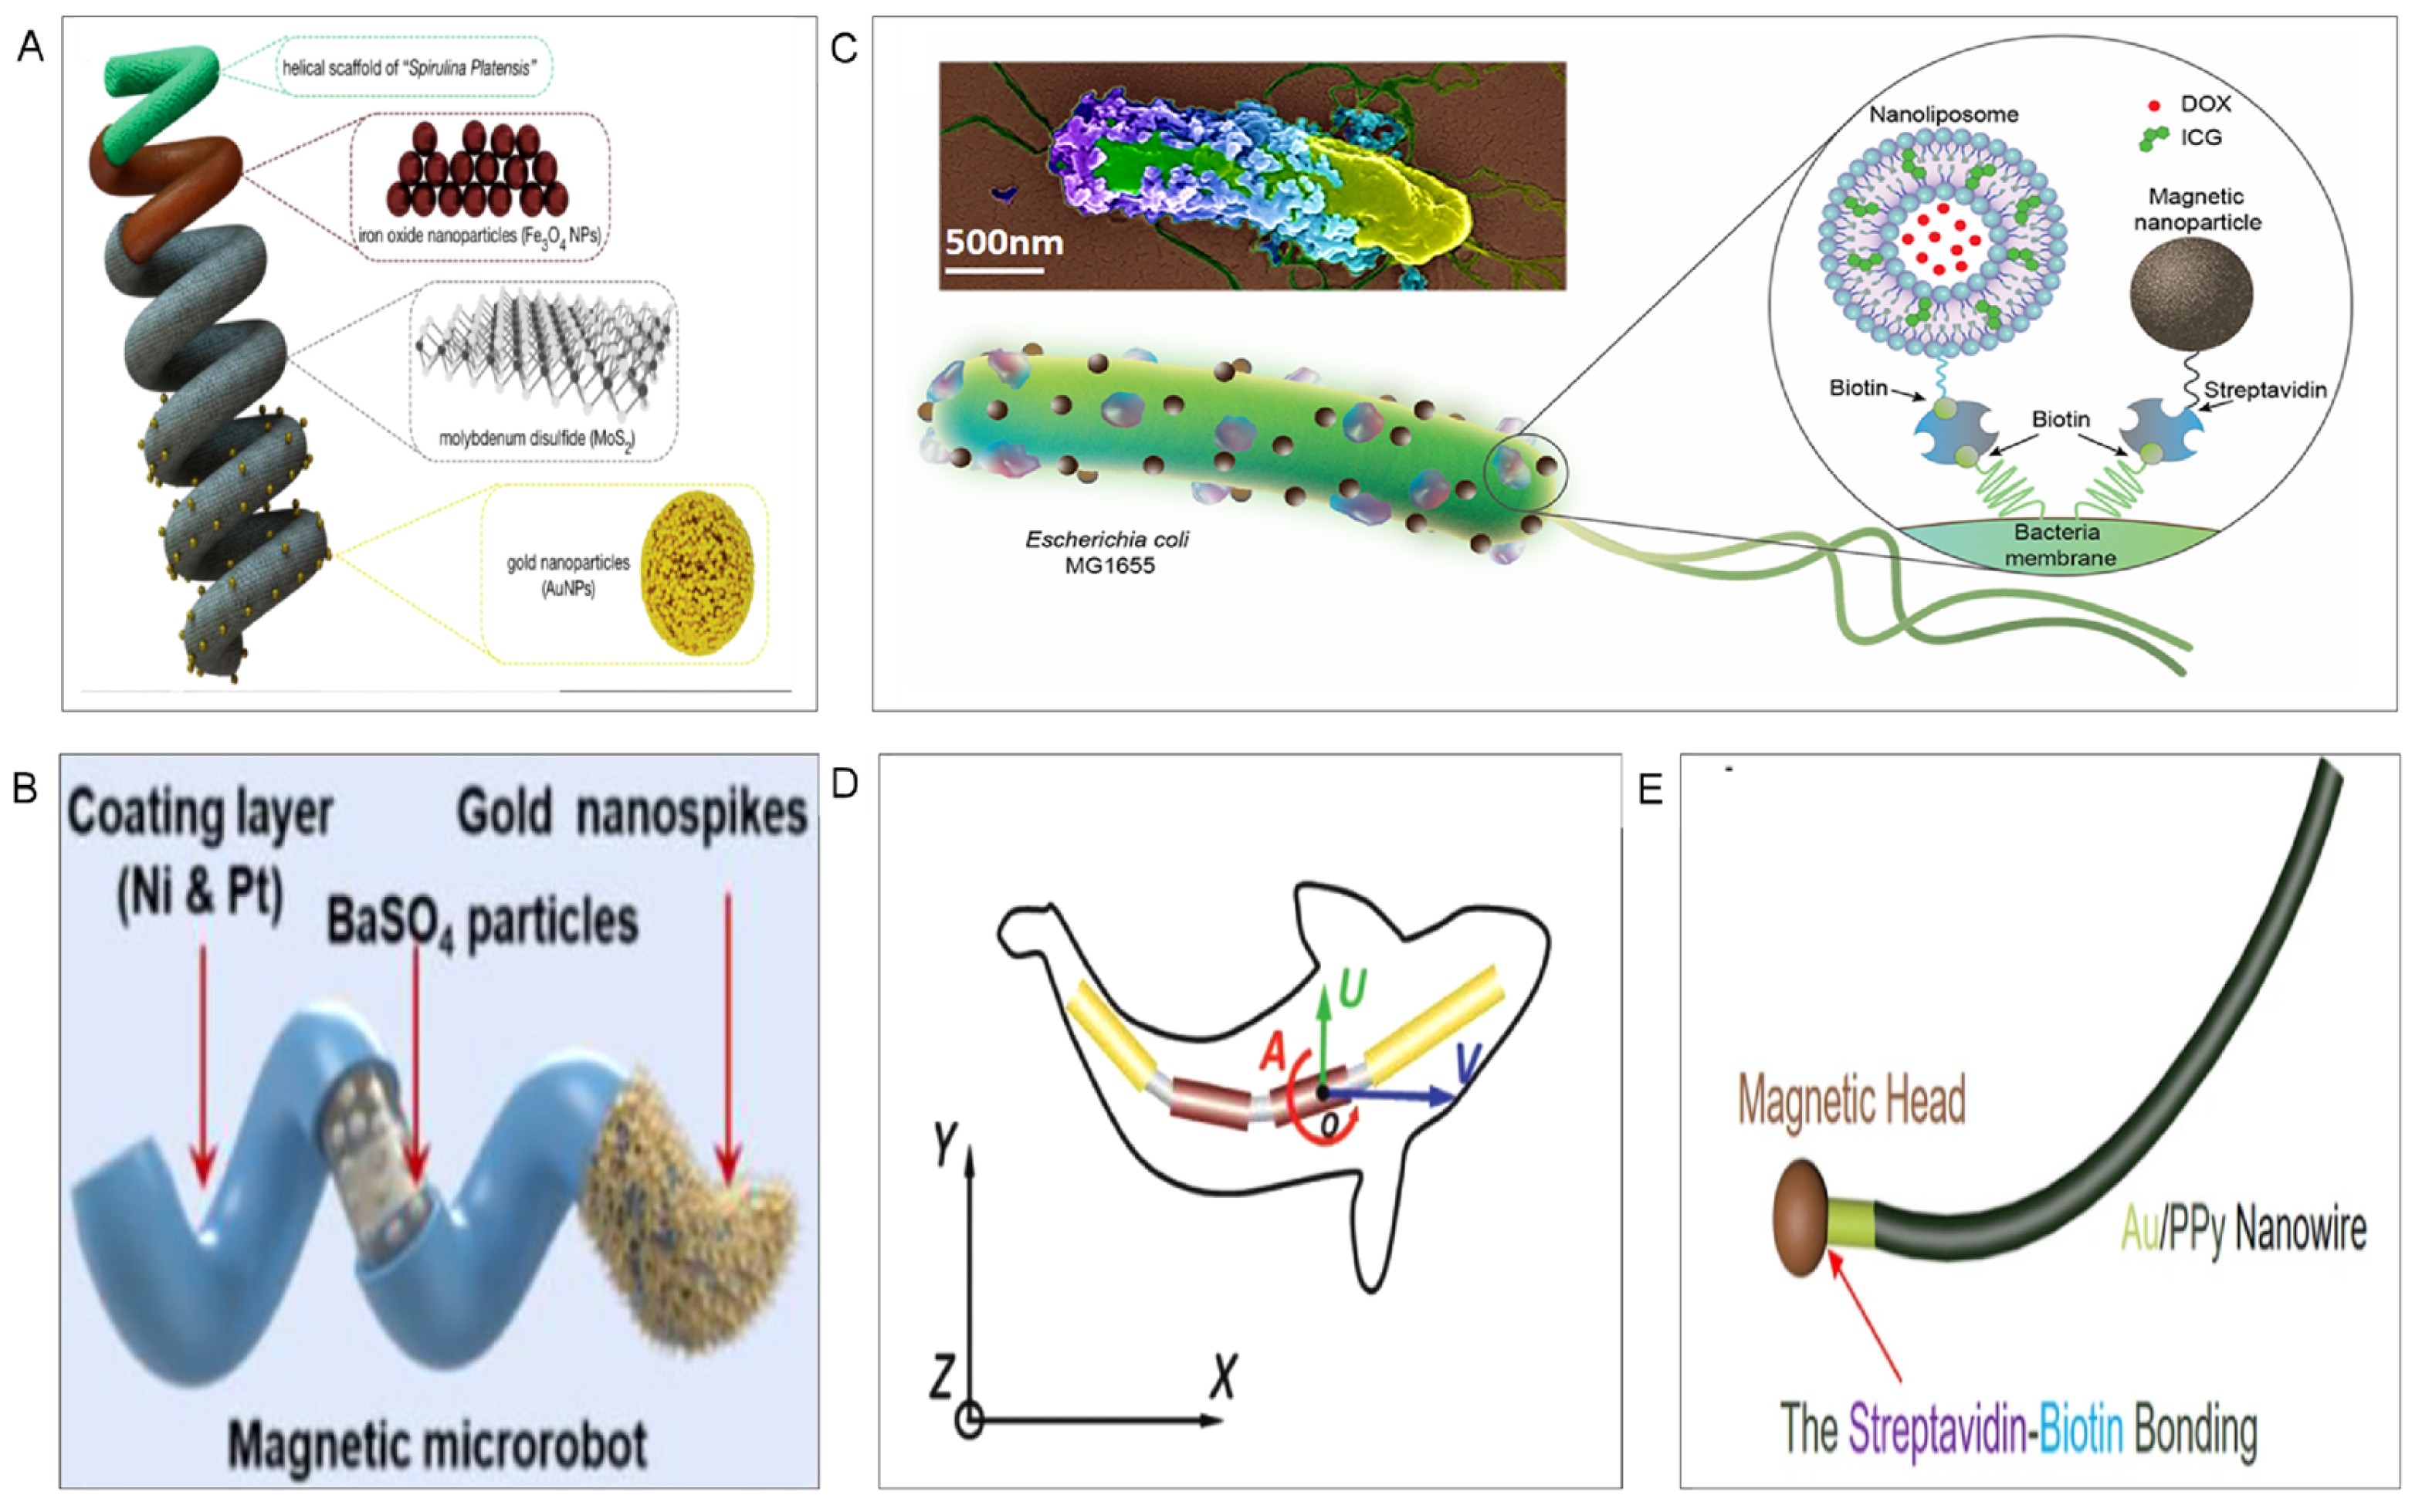
3.4. Bio-Inspired and Biotemplated Continuum Robots
4. Biomedical Application
4.1. Cardiovascular and Neurointervention
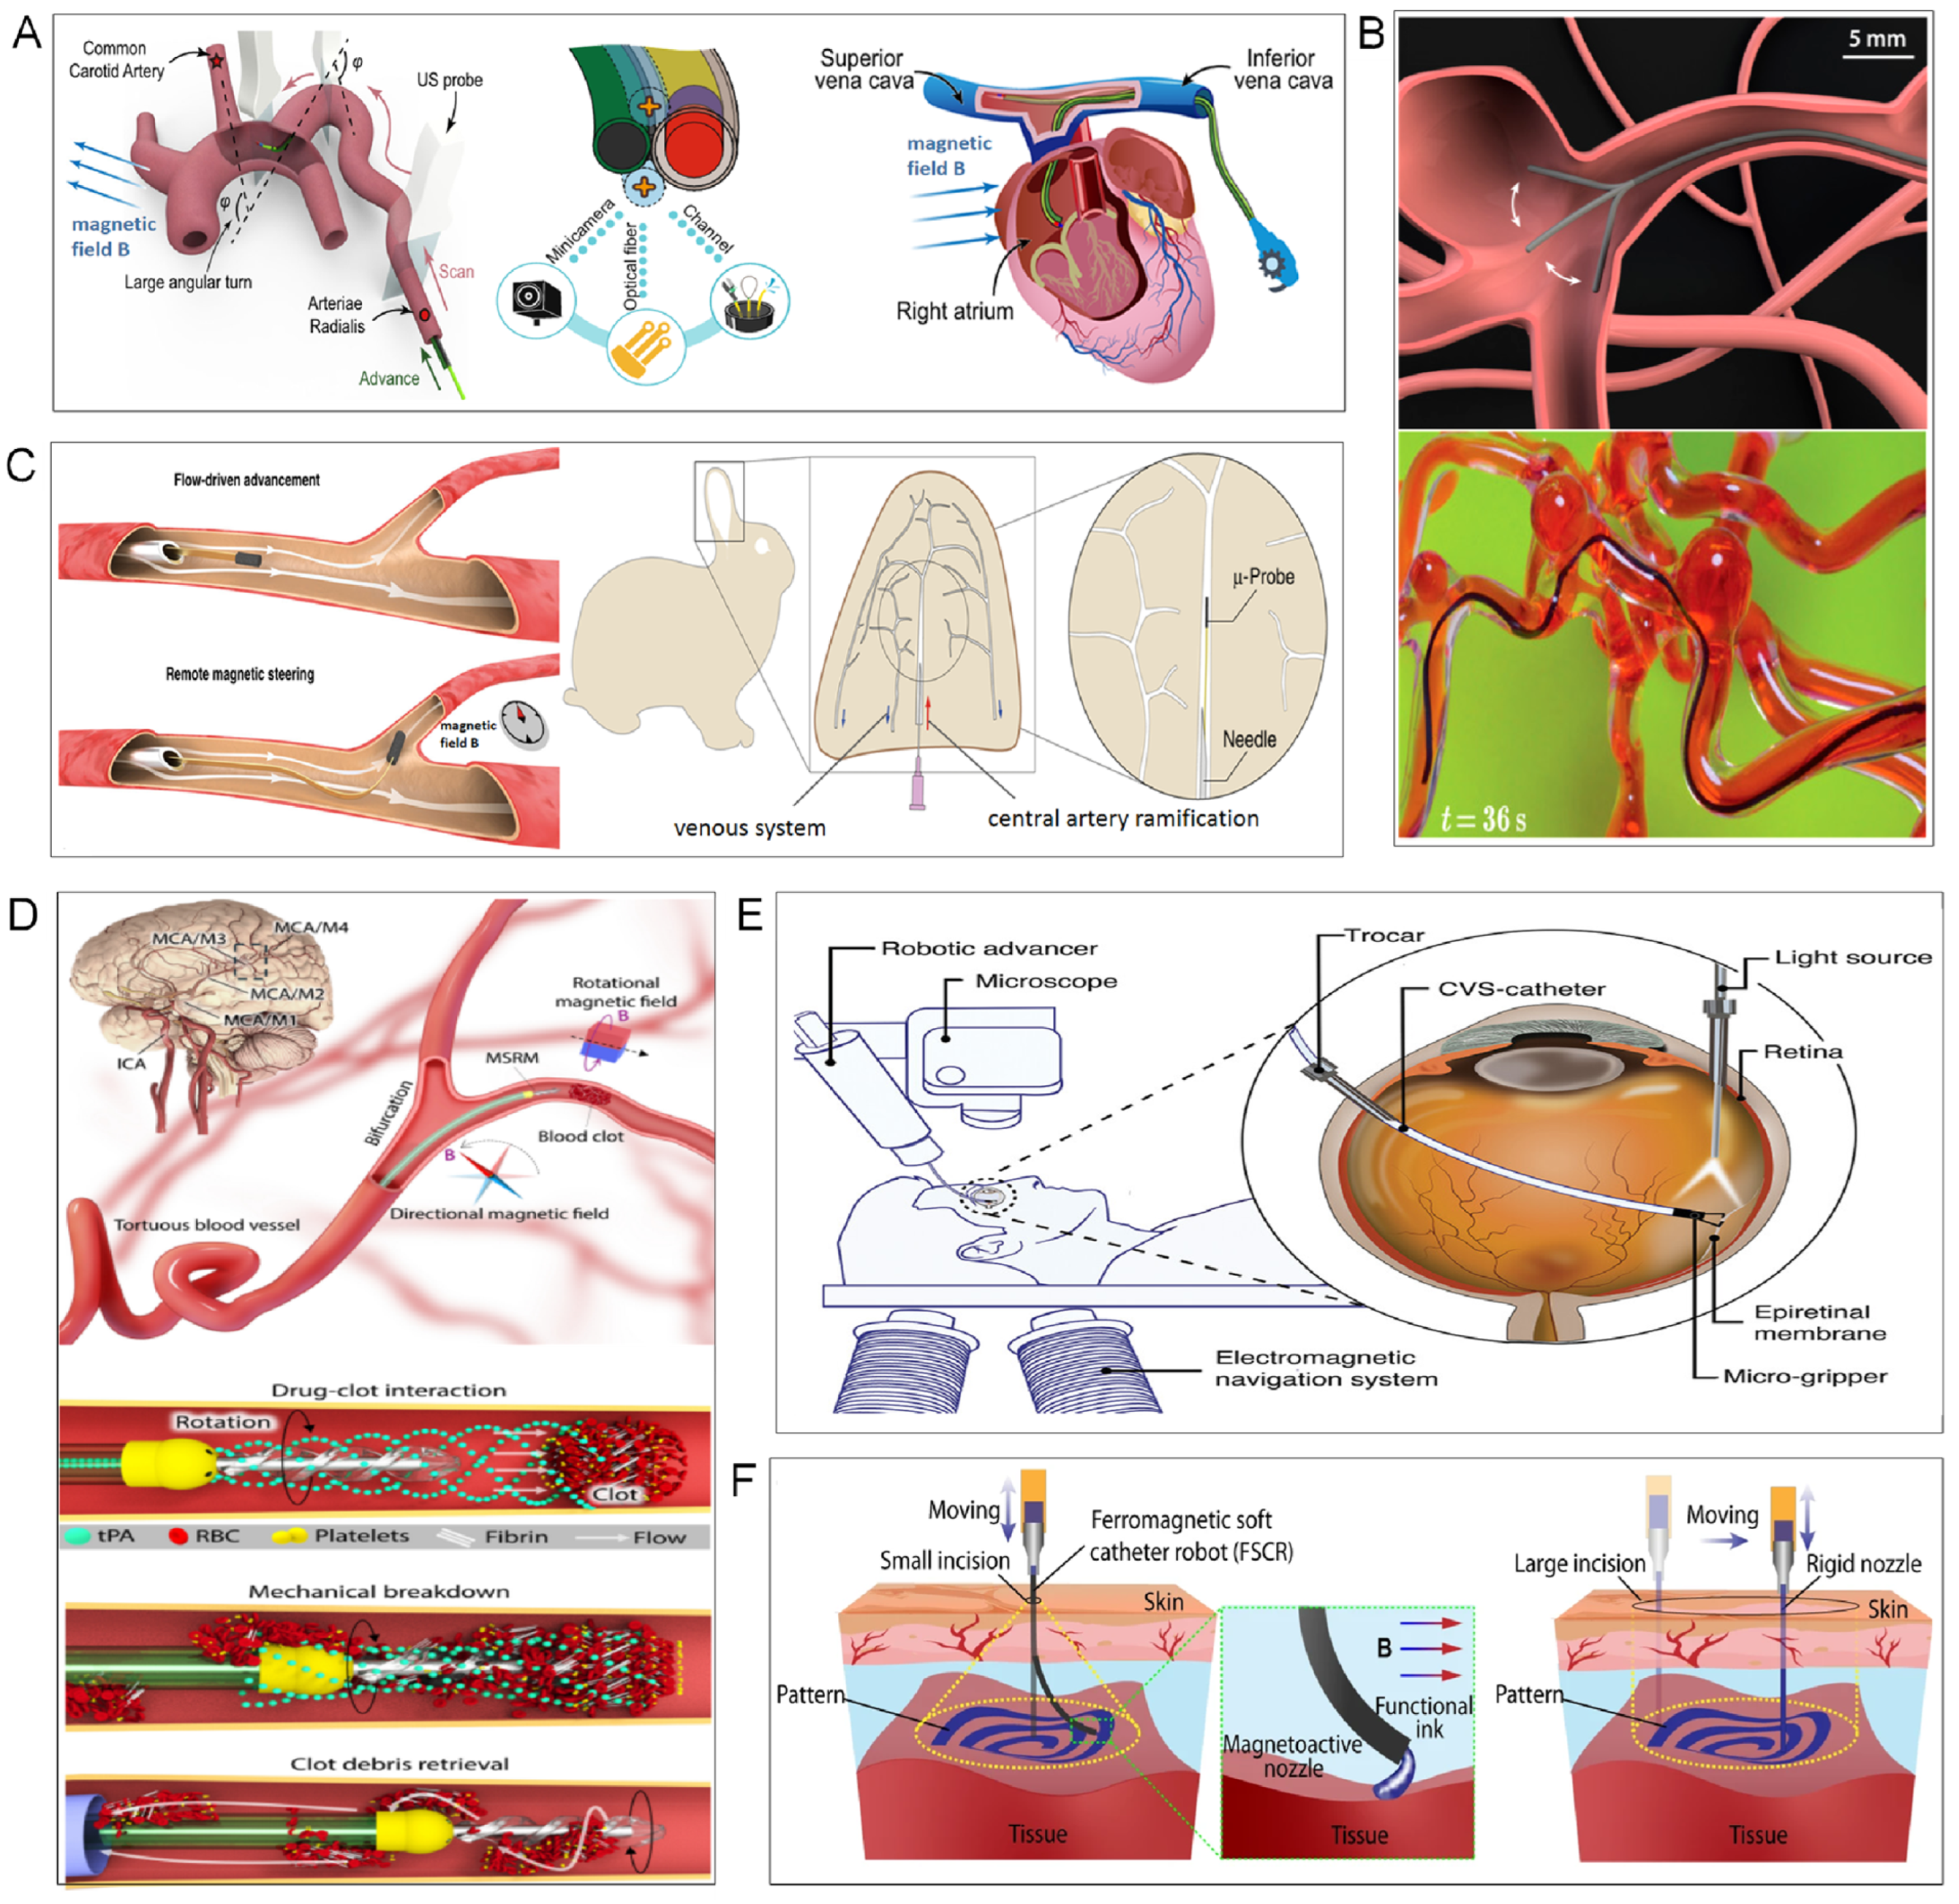
4.2. Intracavitary Intervention
4.3. Minimally Invasive Surgery and Tissue Repair
5. Conclusions and Perspectives
Author Contributions
Funding
Institutional Review Board Statement
Informed Consent Statement
Data Availability Statement
Conflicts of Interest
References
- Pan, L.; Jia, X.; Sun, X.; Li, J.; Zhang, N.; Wang, L. PINNs-enabled inverse programming of magnetic soft continuum robots: Shape morphing and tip trajectory. Sci. China Phys. Mech. Astron. 2025, 69, 224612. [Google Scholar] [CrossRef] [Scilit]
- Yang, Y.; Shi, W.; Yang, B.; Xiong, T.; Li, Z.A.; Ren, H. Regrafting submillimeter-scale ferromagnetic soft continuums. Nat. Commun. 2025, 16, 7023. [Google Scholar] [CrossRef] [Scilit]
- Fu, S.; Dong, S.; Shen, H.; Chen, Z.; Ma, G.; Cai, M.; Huang, C.; Peng, Q.; Bai, C.; Dong, Y.; et al. Multifunctional Magnetic Catheter Robot with Triaxial Force Sensing Capability for Minimally Invasive Surgery. Research 2025, 8, 0681. [Google Scholar] [CrossRef] [Scilit]
- Kwok, K.-W.; Hung Tsoi, K.; Vitiello, V.; Clark, J.; Chow, G.C.T.; Luk, W.; Yang, G.-Z. Dimensionality Reduction in Controlling Articulated Snake Robot for Endoscopy Under Dynamic Active Constraints. IEEE Trans. Robot. 2013, 29, 15–31. [Google Scholar] [CrossRef] [Scilit]
- Mitros, Z.; Sadati, S.; Seneci, C.; Bloch, E.; Leibrandt, K.; Khadem, M.; da Cruz, L.; Bergeles, C. Optic Nerve Sheath Fenestration with a Multi-Arm Continuum Robot. IEEE Robot. Autom. Lett. 2020, 5, 4874–4881. [Google Scholar] [CrossRef] [Scilit]
- Wang, X.; Fang, G.; Wang, K.; Xie, X.; Lee, K.-H.; Ho, J.D.L.; Tang, W.L.; Lam, J.; Kwok, K.-W. Eye-in-Hand Visual Servoing Enhanced with Sparse Strain Measurement for Soft Continuum Robots. IEEE Robot. Autom. Lett. 2020, 5, 2161–2168. [Google Scholar] [CrossRef] [Scilit]
- Kim, Y.; Genevriere, E.; Harker, P.; Choe, J.; Balicki, M.; Patel, A.B.; Zhao, X. Telerobotically Controlled Magnetic Soft Continuum Robots for Neurovascular Interventions. In Proceedings of the 2022 International Conference on Robotics and Automation (ICRA), Philadelphia, PA, USA, 23–27 May 2022. [Google Scholar]
- Wang, Z.; Weng, D.; Li, Z.; Chen, L.; Ma, Y.; Wang, J. A Magnetic-Controlled Flexible Continuum Robot with Different Deformation Modes for Vascular Interventional Navigation Surgery. Actuators 2023, 12, 247. [Google Scholar] [CrossRef] [Scilit]
- Dupourqué, L.; Masaki, F.; Colson, Y.L.; Kato, T.; Hata, N. Transbronchial biopsy catheter enhanced by a multisection continuum robot with follow-the-leader motion. Int. J. Comput. Assist. Radiol. Surg. 2019, 14, 2021–2029. [Google Scholar] [CrossRef] [Scilit]
- Shi, J.; Abad, S.-A.; Dai, J.S.; Wurdemann, H.A. Position and Orientation Control for Hyperelastic Multisegment Continuum Robots. IEEE/ASME Trans. Mechatron. 2024, 29, 995–1006. [Google Scholar] [CrossRef] [Scilit]
- Pekris, S.; Williams, R.D.; Atkins, T.; Georgilas, I.; Bailey, N. Model-based trajectory tracking of a compliant continuum robot. Front. Robot. AI 2024, 11, 1358857. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Wang, X.; Lu, Q.; Lee, D.; Gan, Z.; Rojas, N. A Soft Continuum Robot with Self-Controllable Variable Curvature. IEEE Robot. Autom. Lett. 2024, 9, 2016–2023. [Google Scholar] [CrossRef] [Scilit]
- Abolfathi, K.; Rosales-Medina, J.A.; Khaksar, H.; Chandler, J.H.; McDonald-Maier, K.D.; Ashkan, K.; Valdastri, P.; Hoshiar, A.K. Independent and Hybrid Magnetic Manipulation for Full Body Controlled Soft Continuum Robots. IEEE Robot. Autom. Lett. 2023, 8, 4235–4242. [Google Scholar] [CrossRef] [Scilit]
- Yang, P.; Mao, L.; Tian, C.; Meng, X.; Xie, H. A Cooperative and Multifunctional Magnetic Continuum Robot for Noninteractive Access, Dexterous Navigation, and Versatile Manipulation. Adv. Funct. Mater. 2024, 35, 2412543. [Google Scholar] [CrossRef] [Scilit]
- Yao, S.; Luo, P.; Liu, L.; Yan, H.; Meng, M.Q.H. Fast-Adaptive Permanent Magnetic Positioning-based Navigation Framework for Continuum Robots in Colonoscopic Biopsy. IEEE/ASME Trans. Mechatron. 2025, 30, 3953–3965. [Google Scholar] [CrossRef] [Scilit]
- Li, X.; Lu, C.; Song, Z.; Ding, W.; Zhang, X.-P. Planar Magnetic Actuation for Soft and Rigid Robots Using a Scalable Electromagnet Array. IEEE Robot. Autom. Lett. 2022, 7, 9264–9270. [Google Scholar] [CrossRef] [Scilit]
- Lee, W.; Jung, E.; Kim, N.; Lee, D.; Kim, S.; Lee, Y.; Jang, G. Robotically Adjustable Magnetic Navigation System for Medical Magnetic Milli/Microrobots. IEEE/ASME Trans. Mechatron. 2024, 29, 3949–3959. [Google Scholar] [CrossRef] [Scilit]
- Moezi, A.; Sedaghati, R.; Rakheja, S. Three-dimensional modeling of hard-magnetic soft continuum robots with composite magnetoactive elastomers under nonuniform magnetic fields. Compos. Part B Eng. 2026, 311, 113174. [Google Scholar] [CrossRef] [Scilit]
- Wang, C.; Frazelle, C.G.; Wagner, J.R.; Walker, I.D. Dynamic Control of Multisection Three-Dimensional Continuum Manipulators Based on Virtual Discrete-Jointed Robot Models. IEEE/ASME Trans. Mechatron. 2021, 26, 777–788. [Google Scholar] [CrossRef] [Scilit]
- Gan, L.T.; Blumenschein, L.H.; Huang, Z.; Okamura, A.M.; Hawkes, E.W.; Fan, J.A. 3D Electromagnetic Reconfiguration Enabled by Soft Continuum Robots. IEEE Robot. Autom. Lett. 2020, 5, 1704–1711. [Google Scholar] [CrossRef] [Scilit]
- Tsang, R.K.; Chung, J.C.K. Adapting Electromagnetic Navigation System for Transoral Robotic-Assisted Skull Base Surgery. Laryngoscope 2019, 130, 1922–1925. [Google Scholar] [CrossRef] [Scilit]
- Zhang, T.; Li, G.; Ren, H.; Yang, L.; Yang, X.; Tan, R.; Tang, Y.; Guo, D.; Zhao, H.; Shang, W.; et al. Sub-millimeter fiberscopic robot with integrated maneuvering, imaging, and biomedical operation abilities. Nat. Commun. 2024, 15, 10874. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Lin, D.; Li, N.; Jiao, N.; Wang, Z.; Liu, L. Kinematic Analysis of Multi-Section Opposite Magnetic Catheter Robots with Solution Multiplicity. IEEE Trans. Autom. Sci. Eng. 2024, 21, 123–134. [Google Scholar] [CrossRef] [Scilit]
- Wang, B.; Sun, H.; Du, J.; Yi, Z.; Liu, X.; Hua, D.; Li, Z.; Chauhan, S.; Vashishtha, G. Kinematic modelling and closed-loop control of a novel soft continuum robot. Knowl.-Based Syst. 2025, 316, 113367. [Google Scholar] [CrossRef] [Scilit]
- Tong, D.; Hao, Z.; Li, J.; Sun, B.; Liu, M.; Wang, L.; Huang, W. Real-time simulation enabled navigation control of magnetic soft continuum robots in confined lumens. J. Mech. Phys. Solids 2025, 203, 106198. [Google Scholar] [CrossRef] [Scilit]
- Zhang, S.; Yang, W.; Ge, J. Endovascular embolization by a magnetic microfiberbot. Natl. Sci. Rev. 2024, 11, nwae117. [Google Scholar] [CrossRef] [Scilit]
- Xu, Y.; Lou, C.; Leung, K.C.-F.; Gong, X.; Xuan, S. Cross-scale magnetic catheter-magnetic swarm strategy for precise thrombus clearance. Extrem. Mech. Lett. 2025, 80, 102411. [Google Scholar] [CrossRef] [Scilit]
- Wang, Y.; Ye, H.; von Arx, D.; Li, Y.; Wang, Y.; Mesot, A.; Franco, C.; Chen, X.-Z.; Wang, Y.; Zhang, S.; et al. Magnetic continuum soft robot-driven precise delivery of prodrug nanoassemblies for gastric cancer chemo-immunotherapy. Asian J. Pharm. Sci. 2025, 20, 101103. [Google Scholar] [CrossRef] [Scilit]
- Wang, Z.; Wang, T.; Zhao, B.; He, Y.; Hu, Y.; Li, B.; Zhang, P.; Meng, M.Q.H. Hybrid Adaptive Control Strategy for Continuum Surgical Robot Under External Load. IEEE Robot. Autom. Lett. 2021, 6, 1407–1414. [Google Scholar] [CrossRef] [Scilit]
- Xu, S.; He, B.; Zhou, Y.; Wang, Z.; Zhang, C. A Hybrid Position/Force Control Method for a Continuum Robot with Robotic and Environmental Compliance. IEEE Access 2019, 7, 100467–100479. [Google Scholar] [CrossRef] [Scilit]
- Wang, P.; Guo, S.; Wang, X.; Wu, Y. Design and Analysis of a Novel Variable Stiffness Continuum Robot with Built-in Winding-Styled Ropes. IEEE Robot. Autom. Lett. 2022, 7, 6375–6382. [Google Scholar] [CrossRef] [Scilit]
- Lin, D.; Jiao, N.; Wang, Z.; Liu, L. A Magnetic Continuum Robot with Multi-Mode Control Using Opposite-Magnetized Magnets. IEEE Robot. Autom. Lett. 2021, 6, 2485–2492. [Google Scholar] [CrossRef] [Scilit]
- Chen, Y.; Xu, Z.; Xu, Q. Design and Testing of a Hollow Continuum Magnetic Millirobot with Multimodal Motion. Actuators 2022, 11, 269. [Google Scholar] [CrossRef] [Scilit]
- Wu, Z.; Luo, Q.; Zhan, S.; Yao, L.; Lv, Z.; Wei, F. Multimodal Motion Soft Magnetic Reconfigurable Robot Based on Penetrating Heating. Adv. Mater. Technol. 2025, 11, e01526. [Google Scholar] [CrossRef] [Scilit]
- Deng, L.; Zhou, C.; Wang, J.; Fan, J.; Liao, X.; Zhu, C. Design and Modeling of a Sperm-Inspired Helical Propulsion Robot. IEEE Robot. Autom. Lett. 2023, 8, 8168–8175. [Google Scholar] [CrossRef] [Scilit]
- Liu, D.; Liu, X.; Chen, Z.; Zuo, Z.; Tang, X.; Huang, Q.; Arai, T. Magnetically Driven Soft Continuum Microrobot for Intravascular Operations in Microscale. Cyborg Bionic Syst. 2022, 2022, 9850832. [Google Scholar] [CrossRef] [Scilit]
- Sun, Y.; Zhu, X.; Li, J.; Chen, S.; Li, L.; Cao, Q. Design and implementation of a hybrid magnetic actuation system for magnetic continuum intervention robots. Sens. Actuators A Phys. 2025, 396, 117167. [Google Scholar] [CrossRef] [Scilit]
- Yang, Z.; Yang, H.; Cao, Y.; Cui, Y.; Zhang, L. Magnetically Actuated Continuum Medical Robots: A Review. Adv. Intell. Syst. 2023, 5, 2200416. [Google Scholar] [CrossRef] [Scilit]
- Lin, D.; Wang, J.; Jiao, N.; Wang, Z.; Liu, L. A Flexible Magnetically Controlled Continuum Robot Steering in the Enlarged Effective Workspace with Constraints for Retrograde Intrarenal Surgery. Adv. Intell. Syst. 2021, 3, 2000211. [Google Scholar] [CrossRef] [Scilit]
- Mallahi Kolahi, P.; Habibnejad Korayem, M. Dynamic model-based design of a hybrid neural network and sliding mode controller for real-time and accurate control of ferromagnetic continuum robots. Int. J. Dyn. Control 2025, 13, 313. [Google Scholar] [CrossRef] [Scilit]
- Liu, D.; Liu, X.; Du, J.; Zuo, Z.; Tang, X.; Huang, Q.; Arai, T.; Hu, Y.; Jin, H. A Flexible Magnetic Soft Continuum Robot for Manipulation and Measurement at Microscale. Cardiovasc. Innov. Appl. 2023, 8, e950. [Google Scholar] [CrossRef] [Scilit]
- Sangsefidi, N.; Korayem, H. Body Shape Control of Magnetic Soft Continuum Robots with PID Controller. In Proceedings of the 2023 11th RSI International Conference on Robotics and Mechatronics (ICRoM), Tehran, Iran, 19–21 December 2023. [Google Scholar]
- Zhang, Z.; Klingner, A.; Misra, S.; Khalil, I.S.M. Design and control of a permanent magnet-based robotic system for navigating tetherless magnetic devices in viscous environments. Sci. Rep. 2025, 15, 31041. [Google Scholar] [CrossRef] [Scilit]
- Kim, Y.; Parada, G.A.; Liu, S.; Zhao, X. Ferromagnetic soft continuum robots. Sci. Robot. 2019, 4, eaax7329. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Xu, R.; Wang, X.; Chen, Y.; Tam, L.M.; Xu, Q. Bio-inspired magnetic soft robots with omnidirectional climbing for multifunctional biomedical applications. Int. J. Extrem. Manuf. 2025, 8, 015502. [Google Scholar] [CrossRef] [Scilit]
- Yang, Z.; Zhang, L. Magnetic Actuation Systems for Miniature Robots: A Review. Adv. Intell. Syst. 2020, 2, 2000082. [Google Scholar] [CrossRef] [Scilit]
- Dreyfus, R.; Boehler, Q.; Nelson, B.J. A Simulation Framework for Magnetic Continuum Robots. IEEE Robot. Autom. Lett. 2022, 7, 8370–8376. [Google Scholar] [CrossRef] [Scilit]
- Liu, T.; Zhang, G.; Du, F.; Zhang, X.; He, C.; Li, Y.; Song, R. Magnetic continuum robot: Design, modeling and verification. Int. J. Mech. Sci. 2025, 301, 110460–110472. [Google Scholar] [CrossRef] [Scilit]
- Alessi, C.; Agabiti, C.; Caradonna, D.; Laschi, C.; Renda, F.; Falotico, E. Rod models in continuum and soft robot control: A review. arXiv 2024, arXiv:2407.05886. [Google Scholar]
- Liu, J.; Yang, Y.; Li, M.; Xu, F. A meshfree model of hard-magnetic soft materials. Int. J. Mech. Sci. 2023, 258, 108566–108575. [Google Scholar] [CrossRef] [Scilit]
- Kalekeyeva, M.; Konakbay, Z.; Imanbekova, M.; Shakbutova, A.; Garmash, O.; Muratbekova, G.; Mambetalin, D. Continuum Robots: Current Trends in Design, Control, and Applications. IEEE Access 2025, 13, 106771–106792. [Google Scholar] [CrossRef] [Scilit]
- Civalek, Ö.; Demir, Ç. Bending analysis of microtubules using nonlocal Euler–Bernoulli beam theory. Appl. Math. Model. 2011, 35, 2053–2067. [Google Scholar] [CrossRef] [Scilit]
- Hafner, C.; Bickel, B. The Design Space of Kirchhoff Rods. ACM Trans. Graph. 2023, 42, 171. [Google Scholar] [CrossRef] [Scilit]
- Alqumsan, A.A.; Khoo, S.; Norton, M. Robust control of continuum robots using Cosserat rod theory. Mech. Mach. Theory 2019, 131, 48–61. [Google Scholar] [CrossRef] [Scilit]
- Zhang, T.; Yang, L.; Yang, X.; Tan, R.; Lu, H.; Shen, Y. Millimeter-Scale Soft Continuum Robots for Large-Angle and High-Precision Manipulation by Hybrid Actuation. Adv. Intell. Syst. 2021, 3, 2000189. [Google Scholar] [CrossRef] [Scilit]
- Meng, L.W.; Xie, X.L.; Zhou, X.H.; Liu, S.Q.; Hou, Z.G. Design, Optimization, and Modeling of a Hydraulic Soft Robot for Chronic Total Occlusions. Biomimetics 2024, 9, 163. [Google Scholar] [CrossRef] [Scilit]
- Wang, L.; Zheng, D.; Harker, P.; Patel, A.B.; Guo, C.F.; Zhao, X. Evolutionary design of magnetic soft continuum robots. Proc. Natl. Acad. Sci. USA 2021, 118, e2021922118. [Google Scholar] [CrossRef] [Scilit]
- Wang, J.; Wang, D.; Dong, L.; Zhang, M.; Gu, G. Analytical Modeling and Inverse Design of Centimeter-Scale Hard-Magnetic Soft Robots. IEEE Trans. Autom. Sci. Eng. 2024, 21, 5558–5569. [Google Scholar] [CrossRef] [Scilit]
- Wei, S.; Wu, Z.; Zhang, J. Multimodal Motion Control of Magnetic Continuum Robot for Endovascular Intervention Navigation. IEEE/ASME Trans. Mechatron. 2025, 30, 5734–5744. [Google Scholar] [CrossRef] [Scilit]
- Peyron, Q.; Boehler, Q.; Rabenorosoa, K.; Nelson, B.J.; Renaud, P.; Andreff, N. Kinematic Analysis of Magnetic Continuum Robots Using Continuation Method and Bifurcation Analysis. IEEE Robot. Autom. Lett. 2018, 3, 3646–3653. [Google Scholar] [CrossRef] [Scilit]
- Wang, L.; Kim, Y.; Guo, C.F.; Zhao, X. Hard-magnetic elastica. J. Mech. Phys. Solids 2020, 142, 104045. [Google Scholar] [CrossRef] [Scilit]
- Wang, L.; Guo, C.F.; Zhao, X. Magnetic soft continuum robots with contact forces. Extrem. Mech. Lett. 2022, 51, 101604. [Google Scholar] [CrossRef] [Scilit]
- Li, J.; Wang, L. Modeling magnetic soft continuum robot in nonuniform magnetic fields via energy minimization. Int. J. Mech. Sci. 2024, 282, 109688. [Google Scholar] [CrossRef] [Scilit]
- Mallahi Kolahi, P.; Habibnejad Korayem, M. Dynamic modeling and guidance analysis of a ferromagnetic continuum robot with geometric discretization and base linear motion. Eng. Res. Express 2025, 7, 015232. [Google Scholar] [CrossRef] [Scilit]
- Wang, C.; Jin, T.; Ren, H.; Zhang, H.; Zhao, J. Modeling and design of pre-set stiffness continuum robot. Int. J. Mech. Sci. 2025, 295, 110224. [Google Scholar] [CrossRef] [Scilit]
- Cao, Y.; Cai, M.; Sun, B.; Qi, Z.; Xue, J.; Jiang, Y.; Hao, B.; Zhu, J.; Liu, X.; Yang, C.; et al. Magnetic Continuum Robot with Modular Axial Magnetization: Design, Modeling, Optimization, and Control. IEEE Trans. Robot. 2025, 41, 1513–1532. [Google Scholar] [CrossRef] [Scilit]
- Kolahi, P.M.; Korayem, M.H. Investigation and improving modeling and control for continuum magnetic robots using Cosserat theories and optimal control. Acta Mech. 2024, 235, 3095–3110. [Google Scholar] [CrossRef] [Scilit]
- Wu, Z.; Zhang, J. Closed-Loop Magnetic Control of Medical Soft Continuum Robots for Deflection. IEEE/ASME Trans. Mechatron. 2025, 30, 3607–3618. [Google Scholar] [CrossRef] [Scilit]
- Shao, Y.; Fahmy, A.; Li, M.; Li, C.; Zhao, W.; Sienz, J. Study on Magnetic Control Systems of Micro-Robots. Front. Neurosci. 2021, 15, 736730. [Google Scholar] [CrossRef] [Scilit]
- Zablotskii, V.; Polyakova, T. Permanent magnets in magnetic medicine: Applications and advances. Magn. Med. 2025, 1, 100024. [Google Scholar] [CrossRef] [Scilit]
- Sokolich, M.; Rivas, D.; Yang, Y.; Duey, M.; Das, S. ModMag: A modular magnetic micro-robotic manipulation device. MethodsX 2023, 10, 102171. [Google Scholar] [CrossRef] [Scilit]
- Hwang, J.; Jeon, S.; Kim, B.; Kim, J.y.; Jin, C.; Yeon, A.; Yi, B.J.; Yoon, C.H.; Park, H.J.; Pané, S.; et al. An Electromagnetically Controllable Microrobotic Interventional System for Targeted, Real-Time Cardiovascular Intervention. Adv. Healthc. Mater. 2022, 11, 2102529. [Google Scholar] [CrossRef] [Scilit]
- Zhang, P.; Qing, W.; Lai, X.; Wang, Y.; Wu, M. Cooperative control of multiple magnetically controlled soft robots. Inf. Sci. 2024, 677, 120790. [Google Scholar] [CrossRef] [Scilit]
- Hou, Y.; Wang, H.; Fu, R.; Wang, X.; Yu, J.; Zhang, S.; Huang, Q.; Sun, Y.; Fukuda, T. A review on microrobots driven by optical and magnetic fields. Lab. Chip 2023, 23, 848–868. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Kong, T.; Zheng, Q.; Sun, J.; Wang, C.; Liu, H.; Gao, Z.; Qiao, Z.; Yang, W. Advances in Magnetically Controlled Medical Robotics: A Review of Actuation Systems, Continuum Designs, and Clinical Prospects for Minimally Invasive Therapies. Micromachines 2025, 16, 561. [Google Scholar] [CrossRef] [Scilit]
- Sun, Y.; Sun, B.; Cui, X.; Li, W.; Zhang, Y.; He, L.; Nong, S.; Zhu, Z.; Wu, J.; Li, D.; et al. Addressable and perceptible dynamic reprogram of ferromagnetic soft machines. Nat. Commun. 2025, 16, 2267. [Google Scholar] [CrossRef] [Scilit]
- Li, H.; Zhang, Z.; Yi, X.; Jin, S.; Chen, Y. Control of Self-Winding Microrobot Using an Electromagnetic Drive System: Integration of Movable Electromagnetic Coil and Permanent Magnet. Micromachines 2024, 15, 438. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Li, M.; Wu, J.; Li, N.; Zhou, J.; Cheng, W.; Wu, A.; Liu, L.; Jiao, N. Cross-Scale Drug Delivery of Diatom Microrobots Based on A Magnetic Continuum Robot for Combined Chemical and Photodynamic Therapy of Glioblastoma. Adv. Funct. Mater. 2024, 34, 2402333. [Google Scholar] [CrossRef] [Scilit]
- Chen, Y.; Tong, D.; Zhao, Y.; Chen, T.; Fan, X. SCMAS: An IMU-based 6-DOF closed-loop permanent magnet actuation system for magnet agent. Sci. Rep. 2025, 15, 17808. [Google Scholar] [CrossRef] [Scilit]
- Mehrkish, A.; Janabi-Sharifi, F. Grasp synthesis of continuum robots. Mech. Mach. Theory 2022, 168, 104575. [Google Scholar] [CrossRef] [Scilit]
- Yang, P.-a.; Han, Y.; Mo, C.; Luo, J.; Shou, M.; Gong, X.; Zhou, Z. A review and perspective of magnetic-controlled microbots for medical applications. Chem. Eng. J. 2025, 520, 165814. [Google Scholar] [CrossRef] [Scilit]
- Zou, Y.; Liu, Y.; Li, Y.; Yang, L.; Liu, Y.; He, K.; Xiang, Y.; Ouyang, J.; Li, P.; Liang, J.; et al. Magnetically actuated multimaterial fiberbot for precise minimally invasive knee laser surgery. Sci. Adv. 2025, 11, eadt1809. [Google Scholar] [CrossRef] [Scilit]
- Mao, L.; Yang, P.; Tian, C.; Shen, X.; Wang, F.; Zhang, H.; Meng, X.; Xie, H. Magnetic steering continuum robot for transluminal procedures with programmable shape and functionalities. Nat. Commun. 2024, 15, 3759. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Huang, Y.; Zhao, Q.; Hu, J.; Liu, H. Design and Modeling of a Multi-DoF Magnetic Continuum Robot with Diverse Deformation Modes. IEEE Robot. Autom. Lett. 2024, 9, 3956–3963. [Google Scholar] [CrossRef] [Scilit]
- Li, J.; Wan, S.; Tan, L.; Shah, K.; Wang, L. Hard-magnetic soft continuum robots: Modeling, design and applications. Sci. China Phys. Mech. Astron. 2025, 68, 104601. [Google Scholar] [CrossRef] [Scilit]
- Chathuranga, D.; Lloyd, P.; Chandler, J.H.; Harris, R.A.; Valdastri, P. Assisted Magnetic Soft Continuum Robot Navigation via Rotating Magnetic Fields. IEEE Robot. Autom. Lett. 2024, 9, 183–190. [Google Scholar] [CrossRef] [Scilit]
- Wang, H.; Mao, Y.; Du, J. Continuum Robots and Magnetic Soft Robots: From Models to Interdisciplinary Challenges for Medical Applications. Micromachines 2024, 15, 313. [Google Scholar] [CrossRef] [Scilit]
- Xue, J.; Zhang, M.; Liu, X.; Zhu, J.; Cao, Y.; Zhang, L. A Magnetic Continuum Robot with In-situ Magnetic Reprogramming Capability. In Proceedings of the 2024 IEEE International Conference on Robotics and Automation (ICRA), Yokohama, Japan, 13–17 May 2024. [Google Scholar]
- Hoshiar, A.K.; Jeon, S.; Kim, K.; Lee, S.; Kim, J.-y.; Choi, H. Steering Algorithm for a Flexible Microrobot to Enhance Guidewire Control in a Coronary Angioplasty Application. Micromachines 2018, 9, 617. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Li, N.; Lin, D.; Wu, J.; Gan, Q.; Hu, X.; Jiao, N. Novel Concentric Magnetic Continuum Robot with Multiple Stiffness Modes for Potential Delivery of Nanomedicine. Magnetochemistry 2023, 9, 129. [Google Scholar] [CrossRef] [Scilit]
- Kaur, M.; Sondhi, S.; Yanumula, V.K. Design and Optimization of Controller-Based Approach for Magnetic-Field Driven Robotic Arm Joints and End-Effector. J. Field Robot. 2025, 42, 3285–3307. [Google Scholar] [CrossRef] [Scilit]
- Alrumayh, A.; Alhassoon, K.; Alsaleem, F.; Shaban, M.; Alsunaydih, F.N. Electromagnetically Driven Robot for Multipurpose Applications. Appl. Sci. 2025, 15, 973. [Google Scholar] [CrossRef] [Scilit]
- Hu, W.; Lum, G.Z.; Mastrangeli, M.; Sitti, M. Small-scale soft-bodied robot with multimodal locomotion. Nature 2018, 554, 81–85. [Google Scholar] [CrossRef] [Scilit]
- Jeon, S.; Hoshiar, A.K.; Kim, S.; Lee, S.; Kim, E.; Lee, S.; Kim, K.; Lee, J.; Kim, J.-y.; Choi, H. Improving guidewire-mediated steerability of a magnetically actuated flexible microrobot. Micro Nano Syst. Lett. 2018, 6, 15. [Google Scholar] [CrossRef] [Scilit]
- Wang, X.; Liu, W.; Luo, Q.; Yao, L.; Wei, F. Thermally Drawn-Based Microtubule Soft Continuum Robot for Cardiovascular Intervention. ACS Appl. Mater. Interfaces 2024, 16, 29783–29792. [Google Scholar] [CrossRef] [Scilit]
- Rodrigue, H.; Kim, J. Soft actuators in surgical robotics: A state-of-the-art review. Intell. Serv. Robot. 2023, 17, 3–17. [Google Scholar] [CrossRef] [Scilit]
- Khalil, I.S.M.; Tabak, A.F.; Hamed, Y.; Tawakol, M.; Klingner, A.; Gohary, N.E.; Mizaikoff, B.; Sitti, M. Independent Actuation of Two-Tailed Microrobots. IEEE Robot. Autom. Lett. 2018, 3, 1703–1710. [Google Scholar] [CrossRef] [Scilit]
- Wang, J.; Liu, Y.; Lu, X.; Zhu, Y.; Bai, C. Design and Optimization of a Tapered Magnetic Soft Continuum Robot for Enhanced Navigation in Cerebral Vasculature. Micromachines 2025, 16, 701. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Jeon, S.; Hoshiar, A.K.; Kim, K.; Lee, S.; Kim, E.; Lee, S.; Kim, J.Y.; Nelson, B.J.; Cha, H.J.; Yi, B.J.; et al. A Magnetically Controlled Soft Microrobot Steering a Guidewire in a Three-Dimensional Phantom Vascular Network. Soft Robot. 2019, 6, 54–68. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Wang, Q.; Zhang, Z.; Li, B.; Wang, J.; Gu, H. Hard-Magnetic Soft Millirobots in Underactuated Systems. Adv. Robot. Res. 2025, e202500071. [Google Scholar] [CrossRef] [Scilit]
- Kim, Y.; Zhao, X. Magnetic Soft Materials and Robots. Chem. Rev. 2022, 122, 5317–5364. [Google Scholar] [CrossRef] [Scilit]
- Nguyen, K.T.; Lee, H.-S.; Kim, J.; Choi, E.; Park, J.-O.; Kim, C.-S. A composite electro-permanent magnetic actuator for microrobot manipulation. Int. J. Mech. Sci. 2022, 229, 107516. [Google Scholar] [CrossRef] [Scilit]
- Chen, H.; Sitti, M. Physical Intelligence in Small-Scale Robots and Machines. Adv. Mater. 2025, 38, e10332. [Google Scholar] [CrossRef] [Scilit]
- Du, X.; Zhang, M.; Yu, J.; Yang, L.; Chiu, P.W.Y.; Zhang, L. Design and Real-Time Optimization for a Magnetic Actuation System with Enhanced Flexibility. IEEE/ASME Trans. Mechatron. 2021, 26, 1524–1535. [Google Scholar] [CrossRef] [Scilit]
- Sikorski, J.; Heunis, C.M.; Franco, F.; Misra, S. The ARMM System: An Optimized Mobile Electromagnetic Coil for Non-Linear Actuation of Flexible Surgical Instruments. IEEE Trans. Magn. 2019, 55, 5600109. [Google Scholar] [CrossRef] [Scilit]
- Yang, L.; Du, X.; Yu, E.; Jin, D.; Zhang, L. DeltaMag: An Electromagnetic Manipulation System with Parallel Mobile Coils. In Proceedings of the 2019 International Conference on Robotics and Automation (ICRA), Montreal, QC, Canada, 20–24 May 2019; pp. 9814–9820. [Google Scholar]
- Edelmann, J.; Petruska, A.J.; Nelson, B.J. Magnetic control of continuum devices. Int. J. Robot. Res. 2017, 36, 68–85. [Google Scholar] [CrossRef] [Scilit]
- Yang, Z.; Yang, L.; Zhang, L. Autonomous Navigation of Magnetic Microrobots in a Large Workspace Using Mobile-Coil System. IEEE/ASME Trans. Mechatron. 2021, 26, 3163–3174. [Google Scholar] [CrossRef] [Scilit]
- Jha, M.; Chauhan, N.R. A review on Snake-like Continuum Robots for Medical Surgeries. IOP Conf. Ser. Mater. Sci. Eng. 2019, 691, 012093. [Google Scholar] [CrossRef] [Scilit]
- Ma, Y.; An, X.; Yang, Q.; Cai, M.; Tang, Z.; Chang, J.; Iacovacci, V.; Xu, T.; Zhang, L.; Wang, Q. Magnetic Continuum Robot for Intelligent Manipulation in Medical Applications. SmartBot 2025, 1, e12011. [Google Scholar] [CrossRef] [Scilit]
- da Veiga, T.; Chandler, J.H.; Lloyd, P.; Pittiglio, G.; Wilkinson, N.J.; Hoshiar, A.K.; Harris, R.A.; Valdastri, P. Challenges of continuum robots in clinical context: A review. Prog. Biomed. Eng. 2020, 2, 032003. [Google Scholar] [CrossRef] [Scilit]
- Zhong, Y.; Hu, L.; Xu, Y. Recent Advances in Design and Actuation of Continuum Robots for Medical Applications. Actuators 2020, 9, 142. [Google Scholar] [CrossRef] [Scilit]
- Iqbal, F.; Esfandiari, M.; Amirkhani, G.; Hoshyarmanesh, H.; Lama, S.; Tavakoli, M.; Sutherland, G.R. Continuum and Soft Robots in Minimally Invasive Surgery: A Systematic Review. IEEE Access 2025, 13, 24053–24079. [Google Scholar] [CrossRef] [Scilit]
- Huo, Y.; Yang, L.; Xu, T.; Sun, D. Design, Control, and Clinical Applications of Magnetic Actuation Systems: Challenges and Opportunities. Adv. Intell. Syst. 2024, 7, 2400403. [Google Scholar] [CrossRef] [Scilit]
- Mendes Pereira, V.; Rice, H.; De Villiers, L.; Sourour, N.; Clarencon, F.; Spears, J.; Tomasello, A.; Hernandez, D.; Cancelliere, N.M.; Liu, X.Y.E.; et al. Evaluation of effectiveness and safety of the CorPath GRX robotic system in endovascular embolization procedures of cerebral aneurysms. J. Neurointerv. Surg. 2024, 16, 405–411. [Google Scholar] [CrossRef] [Scilit]
- Kiemeneij, F.; Patterson, M.S.; Amoroso, G.; Laarman, G.; Slagboom, T. Use of the Stereotaxis Niobe Magnetic Navigation System for Percutaneous Coronary Intervention: Results from 350 Consecutive Patients. Catheter. Cardiovasc. Interv. 2008, 71, 510–516. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Liu, W.; Luo, Q.; Zhu, X.; Liu, M.; Yao, L.; Wei, F. A Multichannel Continuum Robot for In Situ Diagnosis and Treatment of Vascular Lesions. Sci. Eng. 2025, 11, 3071–3081. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Hu, A.; Sun, Y. Contact Force Estimation of Continuum Robots without Embedded Sensors: A Review. Adv. Intell. Syst. 2025, 8, e202500786. [Google Scholar] [CrossRef] [Scilit]
- Francescon, V.; Murasovs, N.; Lloyd, P.; Onaizah, O.; Chathuranga, D.S.; Valdastri, P. Closed-Loop Shape-Forming Control of a Magnetic Soft Continuum Robot. IEEE Robot. Autom. Lett. 2025, 10, 6071–6078. [Google Scholar] [CrossRef] [Scilit]
- Brockdorff, M.; Calmé, B.; Wang, T.; Tinsley, L.J.; Davy, J.; Lloyd, P.; Chandler, J.H.; Harris, R.A.; Sitti, M.; Valdastri, P. Combining tethered and untethered magnetic robots via a magnetically triggerable latch for target payload delivery and retrieval. Sci. Adv. 2026, 12, eadu6025. [Google Scholar] [CrossRef] [Scilit]
- Fan, Q.; Hou, Z.; Liu, X.; Liu, Y. Collaborative Task Planning for PCB-Driven Magnetic Microrobots Using Deep Reinforcement Learning. IEEE/ASME Trans. Mechatron. 2026, 31, 479–489. [Google Scholar] [CrossRef] [Scilit]
- Beaver, L.E.; Shah, Z.H.; Sokolich, M.; Yilmaz, A.E.; Yang, Y.; Belta, C.; Das, S. Closed-Loop Control for a Heterogeneous Group of Magnetically-Actuated Microrobots. In Proceedings of the 2023 International Conference on Manipulation, Automation and Robotics at Small Scales (MARSS), Abu Dhabi, United Arab Emirates, 9–13 October 2023. [Google Scholar]
- Zhao, Y.; Dong, X.; Li, Y.; Cui, J.; Shi, Q.; Huang, H.-W.; Huang, Q.; Wang, H. Integrated Cross-Scale Manipulation and Modulable Encapsulation of Cell-Laden Hydrogel for Constructing Tissue-Mimicking Microstructures. Research 2024, 7, 0414. [Google Scholar] [CrossRef] [Scilit]
- Tang, X.; Li, Y.; Liu, X.; Liu, D.; Chen, Z.; Arai, T. Vision-Based Automated Control of Magnetic Microrobots. Micromachines 2022, 13, 337. [Google Scholar] [CrossRef] [Scilit]
- Xu, T.; Yu, J.; Yan, X.; Choi, H.; Zhang, L. Magnetic Actuation Based Motion Control for Microrobots: An Overview. Micromachines 2015, 6, 1346–1364. [Google Scholar] [CrossRef] [Scilit]
- Wang, F.; Zhang, Y.; Jin, D.; Jiang, Z.; Liu, Y.; Knoll, A.; Jiang, H.; Ying, Y.; Zhou, M. Magnetic Soft Microrobot Design for Cell Grasping and Transportation. Cyborg Bionic Syst. 2024, 5, 0109. [Google Scholar] [CrossRef] [Scilit]
- Zhong, S.; Hou, Y.; Zheng, Z.; Huang, H.-W.; Shi, Q.; Huang, Q.; Fukuda, T.; Wang, H. Adaptive Shared Cascade Navigation Control of Magnetic Microrobots in Unstructured Dynamic Environments. IEEE Trans. Cybern. 2026, 1–14. [Google Scholar] [CrossRef] [Scilit]
- Zhong, S.; Nie, R.; Zheng, Z.; Hou, Y.; Shi, Q.; Huang, Q.; Fukuda, T.; Wang, H. Magnetically controlled multimodal motion for environmentally adaptive soft millirobots with transformable wheel-leg morphology. Innovation 2026, 7, 101146. [Google Scholar] [CrossRef] [Scilit]
- Raphalen, L.; Ferro, M.; Posselli, N.R.; Robuffo Giordano, P.; Misra, S.; Pacchierotti, C. Constrained Optimization for Safe and Visibility-Aware Shared Control of Magnetically Actuated Microrobots. IEEE Trans. Autom. Sci. Eng. 2026, 23, 7396–7408. [Google Scholar] [CrossRef] [Scilit]
- Nie, R.; Zhong, S.; Hou, Y.; Zheng, Z.; Shi, Q.; Huang, Q.; Fukuda, T.; Wang, H. Hierarchical Multimodal Motion Control of Magnetic Pivot-Walking Millirobotic-Grippers for Autonomous Target Acquisition in Complex Terrains. IEEE Trans. Robot. 2026, 42, 1749–1768. [Google Scholar] [CrossRef] [Scilit]
- Li, Y.; Huo, Y.; Chu, X.; Yang, L. Automated Magnetic Microrobot Control: From Mathematical Modeling to Machine Learning. Mathematics 2024, 12, 2180. [Google Scholar] [CrossRef] [Scilit]
- Xu, S.; Liu, J.; Yang, C.; Wu, X.; Xu, T. A Learning-Based Stable Servo Control Strategy Using Broad Learning System Applied for Microrobotic Control. IEEE Trans. Cybern. 2022, 52, 13727–13737. [Google Scholar] [CrossRef] [Scilit]
- Xu, S.; Xu, T.; Li, D.; Yang, C.; Huang, C.; Wu, X. A Robot Motion Learning Method Using Broad Learning System Verified by Small-Scale Fish-Like Robot. IEEE Trans. Cybern. 2023, 53, 6053–6065. [Google Scholar] [CrossRef] [Scilit]
- Yu, K.; Wu, D.; Zhang, H.; Yu, Z.; Cong, H.; Zhang, Y.; Sun, M. Magnetic navigation of photoacoustic/ultrasound catheters via vision-ultrasound fusion servo control for embodied medical robots. Pattern Recognit. Lett. 2026, 204, 134–141. [Google Scholar] [CrossRef] [Scilit]
- Tang, Y. The Magnetic Continuum Robots for the Treatment of Atrial Fibrillation. IEEE Access 2025, 13, 155355–155366. [Google Scholar] [CrossRef] [Scilit]
- Ju, Y.; Hu, R.; Xie, Y.; Yao, J.; Li, X.; Lv, Y.; Han, X.; Cao, Q.; Li, L. Reconfigurable magnetic soft robots with multimodal locomotion. Nano Energy 2021, 87, 106169. [Google Scholar] [CrossRef] [Scilit]
- Zhang, L.; Chen, Z.; Ran, H.; Azechi, M.; Yang, X.; Huang, W.; Tian, H.; Shen, L.; Peng, F.; Tu, Y. Biomimetic magnetobacterial microrobots for active pneumonia therapy. Nat. Commun. 2025, 16, 7856. [Google Scholar] [CrossRef] [Scilit]
- Tsuchida, K.; Garcia-Garcia, H.M.; van der Giessen, W.J.; McFadden, E.P.; van der Ent, M.; Sianos, G.; Meulenbrug, H.; Ong, A.T.; Serruys, P.W. Guidewire navigation in coronary artery stenoses using a novel magnetic navigation system: First clinical experience. Catheter. Cardiovasc. Interv. 2006, 67, 356–363. [Google Scholar] [CrossRef] [Scilit]
- Krings, T.; Finney, J.; Niggemann, P.; Reinacher, P.; Luck, N.; Drexler, A.; Lovell, J.; Meyer, A.; Sehra, R.; Schauerte, P.; et al. Magnetic versus manual guidewire manipulation in neuroradiology: In vitro results. Neuroradiology 2006, 48, 394–401. [Google Scholar] [CrossRef] [Scilit]
- Lalande, V.; Gosselin, F.P.; Vonthron, M.; Conan, B.; Tremblay, C.; Beaudoin, G.; Soulez, G.; Martel, S. In vivo demonstration of magnetic guidewire steerability in a MRI system with additional gradient coils. Med. Phys. 2015, 42, 969–976. [Google Scholar] [CrossRef] [Scilit]
- Yang, Z.; Yang, L.; Zhang, M.; Wang, Q.; Simon, C.H.; Zhang, L. Magnetic Control of a Steerable Guidewire Under Ultrasound Guidance Using Mobile Electromagnets. IEEE Robot. Autom. Lett. 2021, 6, 1280–1287. [Google Scholar] [CrossRef] [Scilit]
- Tiryaki, M.E.; Elmacıoğlu, Y.G.; Sitti, M. Magnetic guidewire steering at ultrahigh magnetic fields. Sci. Adv. 2023, 9, eadg6438. [Google Scholar] [CrossRef] [Scilit]
- Kim, Y.; Genevriere, E.; Harker, P.; Choe, J.; Balicki, M.; Regenhardt, R.W.; Vranic, J.E.; Dmytriw, A.A.; Patel, A.B.; Zhao, X. Telerobotic neurovascular interventions with magnetic manipulation. Sci. Robot. 2022, 7, eabg9907. [Google Scholar] [CrossRef] [Scilit]
- Zhang, S.; Yin, M.; Lai, Z.; Huang, C.; Wang, C.; Shang, W.; Wu, X.; Zhang, Y.; Xu, T. Design and Characteristics of 3D Magnetically Steerable Guidewire System for Minimally Invasive Surgery. IEEE Robot. Autom. Lett. 2022, 7, 4040–4046. [Google Scholar] [CrossRef] [Scilit]
- Hwang, J.; Kim, J.-y.; Choi, H. A review of magnetic actuation systems and magnetically actuated guidewire- and catheter-based microrobots for vascular interventions. Intell. Serv. Robot. 2020, 13, 1–14. [Google Scholar] [CrossRef] [Scilit]
- Le, V.N.; Nguyen, N.H.; Alameh, K.; Weerasooriya, R.; Pratten, P. Accurate modeling and positioning of a magnetically controlled catheter tip. Med. Phys. 2016, 43, 650–663. [Google Scholar] [CrossRef] [Scilit]
- Zhou, C.; Yang, Y.; Wang, J.; Wu, Q.; Gu, Z.; Zhou, Y.; Liu, X.; Yang, Y.; Tang, H.; Ling, Q.; et al. Ferromagnetic soft catheter robots for minimally invasive bioprinting. Nat. Commun. 2021, 12, 5072. [Google Scholar] [CrossRef] [Scilit]
- Paquet, L.; Solignac, A.; Tse Ve Koon, K.; Ohta, M.; Tsuruoka, N.; Haga, Y.; Fermon, C.; Pannetier-Lecoeur, M.; Ducharne, B. Magnetic tracking for catheterization procedure, using giant-magnetoresistance and space-varying magnetic field free point. Sens. Actuators A Phys. 2025, 383, 116199. [Google Scholar] [CrossRef] [Scilit]
- Li, Z.; Li, J.; Yeerbulati, M.; Liang, S.; Zhang, Y.; Xu, Q. Collaborative Multirobot Navigation-Assisted Magnetic Catheter Guidance and Shape Perception with Vascular Ultrasound and Electromagnetic Tracking. Adv. Intell. Syst. 2025, 7, 2500193. [Google Scholar] [CrossRef] [Scilit]
- Armstrong, A.K.; Liu, Y.; Kelly, J.M.; Krishnamurthy, R.; Swinning, J.; Liu, Y.; Joseph, M.; Jin, N.; Pang, J.; Maier, F.; et al. Feasibility of magnetic resonance imaging-guided cardiac catheterization, angioplasty, and stenting in a commercial wide-bore 0.55T scanner. J. Cardiovasc. Magn. Reson. 2025, 27, 101858. [Google Scholar] [CrossRef] [Scilit]
- Orczykowski, M.; Bak, M.; Kaczmarek, K.; Urbanek, P.; Robert, B.; Dubowski, K.; Warminski, G.; Derejko, P.; Ptaszynski, P.; Sterlinski, M.; et al. Factors Influencing Contact Force in Robotic Magnetic Navigation Ablation. J. Cardiovasc. Electrophysiol. 2025, 36, 855–862. [Google Scholar] [CrossRef] [Scilit]
- Cunningham, L.O.; Ganapathy, A.; Eldeniz, C.; Weisman, J.A.; Lindsay, K.E.; Jammalamadaka, U.; Tappa, K.; Salter, A.; An, H.; Woodard, P.K.; et al. 3D printed vitamin D impregnated catheters for magnetic resonance-guided interventions: Proof of concept and imaging characteristics. 3D Print. Med. 2025, 11, 27. [Google Scholar] [CrossRef] [Scilit]
- Liu, Y.; Mohanraj, T.G.; Rajebi, M.R.; Zhou, L.; Alambeigi, F. Multiphysical Analytical Modeling and Design of A Magnetically Steerable Robotic Catheter for Treatment of Peripheral Artery Disease. IEEE ASME Trans. Mechatron. 2022, 27, 1873–1881. [Google Scholar] [CrossRef] [Scilit]
- Tillander, H. Magnetic guidance of a catheter with articulated steel tip. Acta Radiol. 1951, 35, 62–64. [Google Scholar] [CrossRef] [Scilit]
- Zhang, K.; Krafft, A.J.; Umathum, R.; Maier, F.; Semmler, W.; Bock, M. Real-time MR navigation and localization of an intravascular catheter with ferromagnetic components. Magn. Reson. Mater. Phys. Biol. Med. 2010, 23, 153–163. [Google Scholar] [CrossRef] [Scilit]
- Gosselin, F.P.; Lalande, V.; Martel, S. Characterization of the deflections of a catheter steered using a magnetic resonance imaging system. Med. Phys. 2011, 38, 4994–5002. [Google Scholar] [CrossRef] [Scilit]
- Vonthron, M.; Lalande, V.; Bringout, G.; Tremblay, C.; Martel, S. A MRI-based Integrated Platform for the Navigation of Microdevices and Microrobots. In Proceedings of the 2011 IEEE/RSJ International Conference on Intelligent Robots and Systems, San Francisco, CA, USA, 25–30 September 2011; pp. 1285–1290. [Google Scholar]
- Sikorski, J.; Mohanty, S.; Misra, S. MILiMAC: Flexible Catheter with Miniaturized Electromagnets as a Small-Footprint System for Microrobotic Tasks. IEEE Robot. Autom. Lett. 2020, 5, 5260–5267. [Google Scholar] [CrossRef] [Scilit]
- Sikorski, J.; Heunis, C.M.; Obeid, R.; Venkiteswaran, V.K.; Misra, S. A Flexible Catheter System for Ultrasound-Guided Magnetic Projectile Delivery. IEEE Trans. Robot. 2022, 38, 1959–1972. [Google Scholar] [CrossRef] [Scilit]
- Lin, D.; Chen, W.; He, K.; Jiao, N.; Wang, Z.; Liu, L. Position and Orientation Control of Multisection Magnetic Soft Microcatheters. IEEE/ASME Trans. Mechatron. 2023, 28, 907–918. [Google Scholar] [CrossRef] [Scilit]
- Pittiglio, G.; Donder, A.; Dupont, P.E. Continuum Robot Shape Estimation Using Magnetic Ball Chains. In Proceedings of the 2024 IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), Abu Dhabi, United Arab Emirates, 14–18 October 2024; pp. 11004–11009. [Google Scholar]
- Chautems, C.; Nelson, B.J. The Tethered Magnet: Force and 5-DOF Pose Control for Cardiac Ablation. In Proceedings of the 2017 IEEE International Conference on Robotics and Automation (ICRA), Singapore, 29 May–3 June 2017; pp. 4837–4842. [Google Scholar]
- Chautems, C.; Lyttle, S.; Boehler, Q.; Nelson, B.J. Design and Evaluation of a Steerable Magnetic Sheath for Cardiac Ablations. IEEE Robot. Autom. Lett. 2018, 3, 2123–2128. [Google Scholar] [CrossRef] [Scilit]
- Lloyd, P.; Hoshiar, A.K.; da Veiga, T.; Attanasio, A.; Marahrens, N.; Chandler, J.H.; Valdastri, P. A Learnt Approach for the Design of Magnetically Actuated Shape Forming Soft Tentacle Robots. IEEE Robot. Autom. Lett. 2020, 5, 3937–3944. [Google Scholar] [CrossRef] [Scilit]
- Lloyd, P.; Onaizah, O.; Pittiglio, G.; Vithanage, D.K.; Chandler, J.H.; Valdastri, P. Magnetic Soft Continuum Robots with Braided Reinforcement. IEEE Robot. Autom. Lett. 2022, 7, 9770–9777. [Google Scholar] [CrossRef] [Scilit]
- Kamaraj, M.; Moghimi, N.; Joshi, A.; Rezayof, O.; Barer, A.; Cao, S.; Orkin, R.; Alambeigi, F.; John, J.V. Recent Advances in Handheld and Robotic Bioprinting Approach for Tissue Engineering. Adv. Mater. Technol. 2025, 10, 2500206. [Google Scholar] [CrossRef] [Scilit]
- Yang, X.; Shang, W.; Lu, H.; Liu, Y.; Yang, L.; Tan, R.; Wu, X.; Shen, Y. An agglutinate magnetic spray transforms inanimate objects into millirobots for biomedical applications. Sci. Robot. 2020, 5, eabc8191. [Google Scholar] [CrossRef] [Scilit]
- Lin, B.; Song, S.; Wang, J. Variable stiffness methods of flexible robots for minimally invasive surgery: A review. Biomim. Intell. Robot. 2024, 4, 100168. [Google Scholar] [CrossRef] [Scilit]
- Manti, M.; Cacucciolo, V.; Cianchetti, M. Stiffening in Soft Robotics: A Review of the State of the Art. IEEE Robot. Autom. Mag. 2016, 23, 93–106. [Google Scholar] [CrossRef] [Scilit]
- Tonazzini, A.; Mintchev, S.; Schubert, B.; Mazzolai, B.; Shintake, J.; Floreano, D. Variable Stiffness Fiber with Self-Healing Capability. Adv. Mater. 2016, 28, 10142–10148. [Google Scholar] [CrossRef] [Scilit]
- Gaeta, L.T.; McDonald, K.J.; Kinnicutt, L.; Le, M.; Wilkinson-Flicker, S.; Jiang, Y.; Atakuru, T.; Samur, E.; Ranzani, T. Magnetically induced stiffening for soft robotics. Soft Matter 2023, 19, 2623–2636. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Zhao, R.; Yao, Y.; Luo, Y. Development of a Variable Stiffness over Tube Based on Low-Melting-Point-Alloy for Endoscopic Surgery. J. Med. Devices 2016, 10, 021002. [Google Scholar] [CrossRef] [Scilit]
- Chautems, C.; Tonazzini, A.; Boehler, Q.; Jeong, S.H.; Floreano, D.; Nelson, B.J. Magnetic Continuum Device with Variable Stiffness for Minimally Invasive Surgery. Adv. Intell. Syst. 2019, 2, 1900086. [Google Scholar] [CrossRef] [Scilit]
- Lussi, J.; Mattmann, M.; Sevim, S.; Grigis, F.; De Marco, C.; Chautems, C.; Pane, S.; Puigmarti-Luis, J.; Boehler, Q.; Nelson, B.J. A Submillimeter Continuous Variable Stiffness Catheter for Compliance Control. Adv. Sci. 2021, 8, 2101290. [Google Scholar] [CrossRef] [Scilit]
- Mattmann, M.; De Marco, C.; Briatico, F.; Tagliabue, S.; Colusso, A.; Chen, X.Z.; Lussi, J.; Chautems, C.; Pane, S.; Nelson, B. Thermoset Shape Memory Polymer Variable Stiffness 4D Robotic Catheters. Adv. Sci. 2022, 9, e2103277. [Google Scholar] [CrossRef] [Scilit]
- Mattmann, M.; Boehler, Q.; Chen, X.-Z.; Pané, S.; Nelson, B.J. Shape memory polymer variable stiffness magnetic catheters with hybrid stiffness control. In Proceedings of the 2022 IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), Kyoto, Japan, 23–27 October 2022. [Google Scholar]
- Piskarev, Y.; Sun, Y.; Righi, M.; Boehler, Q.; Chautems, C.; Fischer, C.; Nelson, B.J.; Shintake, J.; Floreano, D. Fast-Response Variable-Stiffness Magnetic Catheters for Minimally Invasive Surgery. Adv. Sci. 2024, 11, e2305537. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Xu, Z.; Chen, Y.; Xu, Q. Spreadable Magnetic Soft Robots with On-Demand Hardening. Research 2023, 6, 0262. [Google Scholar] [CrossRef] [Scilit]
- Qiao, Z.; Gao, Z.; Feng, X.; Liu, H.; Ge, Z.; Yang, W. Engineering a multi-stiffness nested cooperative magnetic continuum robot based on low melting point alloy. Sci. China Technol. Sci. 2025, 68, 1820301. [Google Scholar] [CrossRef] [Scilit]
- Mesot, A.; Boehler, Q.; Heemeyer, F.; Lyttle, S.; Aktaş, B.; Nelson, B.J. Parametric Design of Continuum Robots Using Interlocking Ball Joints. Adv. Intell. Syst. 2025, 7, 2500180. [Google Scholar] [CrossRef] [Scilit]
- Sun, Y.; Piskarev, Y.; Hofstetter, E.H.; Fischer, C.; Boehler, Q.; Stárek, Z.; Nelson, B.J.; Floreano, D. Instant variable stiffness in cardiovascular catheters based on fiber jamming. Sci. Adv. 2025, 11, eadn1207. [Google Scholar] [CrossRef] [Scilit]
- Lloyd, P.; Thomas, T.L.; Venkiteswaran, V.K.; Pittiglio, G.; Chandler, J.H.; Valdastri, P.; Misra, S. A Magnetically-Actuated Coiling Soft Robot with Variable Stiffness. IEEE Robot. Autom. Lett. 2023, 8, 3262–3269. [Google Scholar] [CrossRef] [Scilit]
- Pogue, C.; Rao, P.; Peyron, Q.; Kim, J.; Burgner-Kahrs, J.; Diller, E. Multiple Curvatures in a Tendon-Driven Continuum Robot Using a Novel Magnetic Locking Mechanism. In Proceedings of the 2022 IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), Kyoto, Japan, 23–27 October 2022. [Google Scholar]
- Liu, H.; Teng, X.; Qiao, Z.; Yu, H.; Cai, S.; Yang, W. A concentric tube magnetic continuum robot with multiple stiffness levels and high flexibility for potential endovascular intervention. J. Magn. Magn. Mater. 2024, 597, 172023. [Google Scholar] [CrossRef] [Scilit]
- Nong, S.; Sun, Y.; Sun, B.; Li, X.; Zhu, Z.; Wu, J.; Li, D.; Li, W.; Zhang, S.; Li, M. Annelids-Inspired Modular Design of Multi-Modal Deformation for Magnetic Soft Robots. Adv. Funct. Mater. 2024, 35, 2415690. [Google Scholar] [CrossRef] [Scilit]
- Xiao, B.; Lin, H.; Buckner, E.; Pierce, J.M.; Tosoian, J.J.; Dong, X. Wireless microfluidics-enabled multifunctional miniature soft robots with multimodal locomotion for fluid manipulation. Device 2025, 3, 100713. [Google Scholar] [CrossRef] [Scilit]
- Li, P.; Chen, Y.; Lin, X.; Ye, C.; Zhang, J.; Fang, D.; Liang, C. A survey on magnetically driven continuum robots for biomedical application. Robot. Auton. Syst. 2026, 198, 105316. [Google Scholar] [CrossRef] [Scilit]
- Ren, Z.; Sitti, M. Design and build of small-scale magnetic soft-bodied robots with multimodal locomotion. Nat. Protoc. 2024, 19, 441–486. [Google Scholar] [CrossRef] [Scilit]
- Manamanchaiyaporn, L.; Xu, T.; Wu, X. Magnetic Soft Robot with the Triangular Head–Tail Morphology Inspired by Lateral Undulation. IEEE/ASME Trans. Mechatron. 2020, 25, 2688–2699. [Google Scholar] [CrossRef] [Scilit]
- Huang, H.W.; Sakar, M.S.; Petruska, A.J.; Pane, S.; Nelson, B.J. Soft micromachines with programmable motility and morphology. Nat. Commun. 2016, 7, 12263. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Xu, C.; Yang, Z.; Tan, S.W.K.; Li, J.; Lum, G.Z. Magnetic Miniature Actuators with Six-Degrees-of-Freedom Multimodal Soft-Bodied Locomotion. Adv. Intell. Syst. 2022, 4, 2100259. [Google Scholar] [CrossRef] [Scilit]
- Du, X.; Cui, H.; Xu, T.; Huang, C.; Wang, Y.; Zhao, Q.; Xu, Y.; Wu, X. Reconfiguration, Camouflage, and Color-Shifting for Bioinspired Adaptive Hydrogel-Based Millirobots. Adv. Funct. Mater. 2020, 30, 1909202. [Google Scholar] [CrossRef] [Scilit]
- Joyee, E.B.; Szmelter, A.; Eddington, D.; Pan, Y. 3D Printed Biomimetic Soft Robot with Multimodal Locomotion and Multifunctionality. Soft Robot. 2022, 9, 1–13. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Ren, Z.; Zhang, R.; Soon, R.H.; Liu, Z.; Hu, W.; Onck, P.R.; Sitti, M. Soft-bodied adaptive multimodal locomotion strategies in fluid-filled confined spaces. Sci. Adv. 2021, 7, eabh2022. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Zhang, T.; Li, G.; Yang, X.; Ren, H.; Guo, D.; Wang, H.; Chan, K.; Ye, Z.; Zhao, T.; Zhang, C.; et al. A Fast Soft Continuum Catheter Robot Manufacturing Strategy Based on Heterogeneous Modular Magnetic Units. Micromachines 2023, 14, 911. [Google Scholar] [CrossRef] [Scilit]
- Wu, Y.; Dong, X.; Kim, J.-k.; Wang, C.; Sitti, M. Wireless soft millirobots for climbing three-dimensional surfaces in confined spaces. Sci. Adv. 2022, 8, eabn3431. [Google Scholar] [CrossRef] [Scilit]
- Zhang, J.; Guo, Y.; Hu, W.; Soon, R.H.; Davidson, Z.S.; Sitti, M. Liquid Crystal Elastomer-Based Magnetic Composite Films for Reconfigurable Shape-Morphing Soft Miniature Machines. Adv. Mater. 2021, 33, e2006191. [Google Scholar] [CrossRef] [Scilit]
- Zhao, H.; Li, J.; Chen, Z.; Zhang, Q.; Yang, M.; Sun, D. Design of a Versatile Microrobot for Cargo Delivery. IEEE/ASME Trans. Mechatron. 2024, 29, 2463–2474. [Google Scholar] [CrossRef] [Scilit]
- Zhu, A.; Li, Y.; Zheng, Y.; Yang, L. Bio-inspired Magnetic Helical Miniature Robots: Mechanisms, Control and Biomedical Applications. J. Bionic Eng. 2025, 22, 2805–2830. [Google Scholar] [CrossRef] [Scilit]
- Jia, L.; Su, G.; Zhang, M.; Wen, Q.; Wang, L.; Li, J. Propulsion Mechanisms in Magnetic Microrobotics: From Single Microrobots to Swarms. Micromachines 2025, 16, 181. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Dodampegama, S.; Mudugamuwa, A.; Konara, M.; Perera, N.; De Silva, D.; Roshan, U.; Amarasinghe, R.; Jayaweera, N.; Tamura, H. A Review on the Motion of Magnetically Actuated Bio-Inspired Microrobots. Appl. Sci. 2022, 12, 1542. [Google Scholar] [CrossRef] [Scilit]
- Che, Y.; Song, X.; Zhang, L. Engineering microalgae-based biohybrid robots for biomedical applications. Cell Biomater. 2025, 1, 100103. [Google Scholar] [CrossRef] [Scilit]
- Li, J.; Yu, J. Biodegradable Microrobots and Their Biomedical Applications: A Review. Nanomaterials 2023, 13, 1590. [Google Scholar] [CrossRef] [Scilit]
- Gong, D.; Celi, N.; Xu, L.; Zhang, D.; Cai, J. CuS nanodots-loaded biohybrid magnetic helical microrobots with enhanced photothermal performance. Mater. Today Chem. 2022, 23, 100694. [Google Scholar] [CrossRef] [Scilit]
- Gong, D.; Li, B.; Celi, N.; Cai, J.; Zhang, D. Efficient Removal of Pb(II) from Aqueous Systems Using Spirulina-Based Biohybrid Magnetic Helical Microrobots. ACS Appl. Mater. Interfaces 2021, 13, 53131–53142. [Google Scholar] [CrossRef] [Scilit]
- de la Asuncion-Nadal, V.; Franco, C.; Veciana, A.; Ning, S.; Terzopoulou, A.; Sevim, S.; Chen, X.Z.; Gong, D.; Cai, J.; Wendel-Garcia, P.D.; et al. MoSBOTs: Magnetically Driven Biotemplated MoS(2) -Based Microrobots for Biomedical Applications. Small 2022, 18, e2203821. [Google Scholar] [CrossRef] [Scilit]
- Tottori, S.; Zhang, L.; Qiu, F.; Krawczyk, K.K.; Franco-Obregon, A.; Nelson, B.J. Magnetic helical micromachines: Fabrication, controlled swimming, and cargo transport. Adv. Mater. 2012, 24, 811–816. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Wang, Y.; Jin, D.; Liu, X.; Lin, L.; Cao, H.; Guo, Z.; Sun, X.; Yan, X.; Wang, Q.; Guo, J.; et al. Magnetic Microrobot with Drilling-Sensing Dual Functionality for Targeted Biopsy of Deep-Seated Tracheal Microlesions. Adv. Mater. 2026, 38, e14664. [Google Scholar] [CrossRef] [Scilit]
- Akolpoglu, M.B.; Alapan, Y.; Dogan, N.O.; Baltaci, S.F.; Yasa, O.; Tural, G.A.; Sitti, M. Magnetically steerable bacterial microrobots moving in 3D biological matrices for stimuli-responsive cargo delivery. Sci. Adv. 2022, 8, eabo6163. [Google Scholar] [CrossRef] [Scilit]
- Li, T.; Li, J.; Zhang, H.; Chang, X.; Song, W.; Hu, Y.; Shao, G.; Sandraz, E.; Zhang, G.; Li, L.; et al. Magnetically Propelled Fish-Like Nanoswimmers. Small 2016, 12, 6098–6105. [Google Scholar] [CrossRef] [Scilit]
- Celi, N.; Gong, D.; Cai, J. Artificial flexible sperm-like nanorobot based on self-assembly and its bidirectional propulsion in precessing magnetic fields. Sci. Rep. 2021, 11, 21728. [Google Scholar] [CrossRef] [Scilit]
- Zhang, L.; Abbott, J.J.; Dong, L.; Kratochvil, B.E.; Bell, D.; Nelson, B.J. Artificial bacterial flagella: Fabrication and magnetic control. Appl. Phys. Lett. 2009, 94, 064107. [Google Scholar] [CrossRef] [Scilit]
- Zhou, Y.; Regnier, S.; Sitti, M. Rotating Magnetic Miniature Swimming Robots with Multiple Flexible Flagella. IEEE Trans. Robot. 2014, 30, 3–13. [Google Scholar] [CrossRef] [Scilit]
- Garcia-Torres, J.; Calero, C.; Sagues, F.; Pagonabarraga, I.; Tierno, P. Magnetically tunable bidirectional locomotion of a self-assembled nanorod-sphere propeller. Nat. Commun. 2018, 9, 1663. [Google Scholar] [CrossRef] [Scilit]
- Li, M.; Wu, J.; Lin, D.; Yang, J.; Jiao, N.; Wang, Y.; Liu, L. A diatom-based biohybrid microrobot with a high drug-loading capacity and pH-sensitive drug release for target therapy. Acta Biomater. 2022, 154, 443–453. [Google Scholar] [CrossRef] [Scilit]
- Su, G.; Zheng, L.; Wang, C.; Wang, S.; Wen, Q.; Chen, J.; Jia, L.; Guo, Y.; Li, F.; Huang, H.; et al. Automated Actuation of Biodegradable and Self-Fluorescent Chlorella Swarms Using Magnetic Tweezers. Small 2025, 21, e2408407. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Khalil, I.S.M.; Tabak, A.F.; Hosney, A.; Mohamed, A.; Klingner, A.; Ghoneima, M.; Sitti, M. Sperm-Shaped Magnetic Microrobots: Fabrication using Electrospinning, Modeling, and Characterization. In Proceedings of the 2016 IEEE International Conference on Robotics and Automation (ICRA), Stockholm, Sweden, 16–21 May 2016; pp. 1939–1944. [Google Scholar]
- Williams, B.J.; Anand, S.V.; Rajagopalan, J.; Saif, M.T. A self-propelled biohybrid swimmer at low Reynolds number. Nat. Commun. 2014, 5, 3081. [Google Scholar] [CrossRef] [Scilit]
- Magdanz, V.; Vivaldi, J.; Mohanty, S.; Klingner, A.; Vendittelli, M.; Simmchen, J.; Misra, S.; Khalil, I.S.M. Impact of Segmented Magnetization on the Flagellar Propulsion of Sperm-Templated Microrobots. Adv. Sci. 2021, 8, 2004037. [Google Scholar] [CrossRef] [Scilit]
- Heunis, C.; Sikorski, J.; Misra, S. Flexible Instruments for Endovascular Interventions: Improved Magnetic Steering, Actuation, and Image-Guided Surgical Instruments. IEEE Robot. Autom. Mag. 2018, 25, 71–82. [Google Scholar] [CrossRef] [Scilit]
- Kang, J.; Wang, Y.; Liu, J.; Wang, Z.; Yang, X.; Wang, J.; Wu, J.; Ning, G.; Zhang, B.; Liao, H. A Soft-Tip Hydraulically Steerable Catheter for Enhanced Flexibility and Safety in Vascular Interventions. Adv. Intell. Syst. 2025, 8, 2500099. [Google Scholar] [CrossRef] [Scilit]
- Pancaldi, L.; Dirix, P.; Fanelli, A.; Lima, A.M.; Stergiopulos, N.; Mosimann, P.J.; Ghezzi, D.; Sakar, M.S. Flow driven robotic navigation of microengineered endovascular probes. Nat. Commun. 2020, 11, 6356. [Google Scholar] [CrossRef] [Scilit]
- Fagogenis, G.; Mencattelli, M.; Machaidze, Z.; Rosa, B.; Price, K.; Wu, F.; Weixler, V.; Saeed, M.; Mayer, J.E.; Dupont, P.E. Autonomous robotic intracardiac catheter navigation using haptic vision. Sci. Robot. 2019, 4, eaaw1977. [Google Scholar] [CrossRef] [Scilit]
- Fu, S.; Chen, B.; Li, D.; Han, J.; Xu, S.; Wang, S.; Huang, C.; Qiu, M.; Cheng, S.; Wu, X.; et al. A Magnetically Controlled Guidewire Robot System with Steering and Propulsion Capabilities for Vascular Interventional Surgery. Adv. Intell. Syst. 2023, 5, 2300267. [Google Scholar] [CrossRef] [Scilit]
- Zhang, M.; Yang, L.; Yang, H.; Su, L.; Xue, J.; Wang, Q.; Hao, B.; Jiang, Y.; Chan, K.F.; Sung, J.J.Y.; et al. A magnetically actuated microcatheter with soft rotatable tip for enhanced endovascular access and treatment efficiency. Sci. Adv. 2025, 11, eadv1682. [Google Scholar] [CrossRef] [Scilit]
- Carpi, F.; Pappone, C. Stereotaxis Niobe magnetic navigation system for endocardial catheter ablation and gastrointestinal capsule endoscopy. Expert Rev. Med. Devices. 2009, 6, 487–498. [Google Scholar] [CrossRef] [Scilit]
- Sun, T.; Chen, J.; Zhang, J.; Zhao, Z.; Zhao, Y.; Sun, J.; Chang, H. Application of micro/nanorobot in medicine. Front. Bioeng. Biotechnol. 2024, 12, 1347312. [Google Scholar] [CrossRef] [Scilit]
- Swaney, P.J.; Mahoney, A.W.; Hartley, B.I.; Remirez, A.A.; Lamers, E.; Feins, R.H.; Alterovitz, R.; Webster, R.J., 3rd. Toward Transoral Peripheral Lung Access: Combining Continuum Robots and Steerable Needles. J. Med. Robot. Res. 2017, 2, 1750001. [Google Scholar] [CrossRef] [Scilit]
- Kato, T.; King, F.; Takagi, K.; Hata, N. Robotized Catheter with Enhanced Distal Targeting for Peripheral Pulmonary Biopsy. IEEE/ASME Trans. Mechatron. 2021, 26, 2451–2461. [Google Scholar] [CrossRef] [Scilit]
- Pittiglio, G.; Lloyd, P.; da Veiga, T.; Onaizah, O.; Pompili, C.; Chandler, J.H.; Valdastri, P. Patient-Specific Magnetic Catheters for Atraumatic Autonomous Endoscopy. Soft Robot. 2022, 9, 1120–1133. [Google Scholar] [CrossRef] [Scilit]
- Pittiglio, G.; Chandler, J.H.; da Veiga, T.; Koszowska, Z.; Brockdorff, M.; Lloyd, P.; Barry, K.L.; Harris, R.A.; McLaughlan, J.; Pompili, C.; et al. Personalized magnetic tentacles for targeted photothermal cancer therapy in peripheral lungs. Commun. Eng. 2023, 2, 50. [Google Scholar] [CrossRef] [Scilit]
- Duan, X.; Xie, D.; Zhang, R.; Li, X.; Sun, J.; Qian, C.; Song, X.; Li, C. A Novel Robotic Bronchoscope System for Navigation and Biopsy of Pulmonary Lesions. Cyborg Bionic Syst. 2023, 4, 0013. [Google Scholar] [CrossRef] [Scilit]
- Chen, Z.; Rivkin, B.; Castellanos-Robles, D.; Soldatov, I.; Beyer, L.; Medina-Sanchez, M. Rapid Fabrication of Self-Propelled and Steerable Magnetic Microcatheters for Precision Medicine. Adv. Mater. 2025, e06591, Early View. [Google Scholar] [CrossRef] [Scilit]
- Wu, J.; Jiao, N.; Lin, D.; Li, N.; Ma, T.; Tung, S.; Cheng, W.; Wu, A.; Liu, L. Dual-Responsive Nanorobot-Based Marsupial Robotic System for Intracranial Cross-Scale Targeting Drug Delivery. Adv. Mater. 2024, 36, e2306876. [Google Scholar] [CrossRef] [Scilit]
- Yang, J.; Zhang, Y.; Liu, Z.; Huang, S.; Huang, X.; Wang, Y.; Li, M.; Zheng, S.; Chen, F.; Liu, J.; et al. Magnetically actuated multimodal bioelectronic catheter for minimally invasive surgery and sensing. Nat. Mater. 2025, 24, 2019–2031. [Google Scholar] [CrossRef] [Scilit]
- Phelan, M.F.; Dogan, N.O.; Lazovic, J.; Sitti, M. Design and Development of a Lorentz Force-Based MRI-Driven Neuroendoscope. In Proceedings of the 2022 IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), Kyoto, Japan, 23–27 October 2022. [Google Scholar]
- Pappone, C.; Vicedomini, G.; Manguso, F.; Gugliotta, F.; Mazzone, P.; Gulletta, S.; Sora, N.; Sala, S.; Marzi, A.; Augello, G.; et al. Robotic magnetic navigation for atrial fibrillation ablation. J. Am. Coll. Cardiol. 2006, 47, 1390–1400. [Google Scholar] [CrossRef] [Scilit]
- Charreyron, S.L.; Boehler, Q.; Danun, A.N.; Mesot, A.; Becker, M.; Nelson, B.J. A Magnetically Navigated Microcannula for Subretinal Injections. IEEE Trans. Biomed. Eng. 2021, 68, 119–129. [Google Scholar] [CrossRef] [Scilit]
- Charreyron, S.L.; Zeydan, B.; Nelson, B.J. Shared Control of a Magnetic Microcatheter for Vitreoretinal Targeted Drug Delivery. In Proceedings of the 2017 IEEE International Conference on Robotics and Automation (ICRA), Singapore, 29 May–3 June 2017; pp. 4843–4848. [Google Scholar]
- Charreyron, S.L.; Gabbi, E.; Boehler, Q.; Becker, M.; Nelson, B.J. A Magnetically Steered Endolaser Probe for Automated Panretinal Photocoagulation. IEEE Robot. Autom. Lett. 2019, 4, xvii–xxiii. [Google Scholar] [CrossRef] [Scilit]
- Hu, J.; Hou, Y.; Wangxie, G.; Hu, S.; Liu, A.; Cui, W.; Yang, W.; He, Y.; Fu, J. Magnetic Soft Catheter Robot System for Minimally Invasive Treatments of Articular Cartilage Defects. Soft Robot. 2024, 11, 1032–1042. [Google Scholar] [CrossRef] [Scilit]
- Wang, Y.; Pereira, R.F.; Peach, C.; Huang, B.; Vyas, C.; Bartolo, P. Robotic in situ bioprinting for cartilage tissue engineering. Int. J. Extrem. Manuf. 2023, 5, 032004. [Google Scholar] [CrossRef] [Scilit]
- Jain, P.; Kathuria, H.; Ramakrishna, S.; Parab, S.; Pandey, M.M.; Dubey, N. In Situ Bioprinting: Process, Bioinks, and Applications. ACS Appl. Bio Mater. 2024, 7, 7987–8007. [Google Scholar] [CrossRef] [Scilit]
- Yang, Y.; Yu, Z.; Lu, X.; Dai, J.; Zhou, C.; Yan, J.; Wang, L.; Wang, Z.; Zang, J. Minimally invasive bioprinting for in situ liver regeneration. Bioact. Mater. 2023, 26, 465–477. [Google Scholar] [CrossRef] [Scilit]
- Wang, G.; Mao, X.; Wang, W.; Wang, X.; Li, S.; Wang, Z. Bioprinted research models of urological malignancy. Exploration 2024, 4, 20230126. [Google Scholar] [CrossRef] [Scilit]
- Yang, G.H.; Yeo, M.; Koo, Y.W.; Kim, G.H. 4D Bioprinting: Technological Advances in Biofabrication. Macromol. Biosci. 2019, 19, e1800441. [Google Scholar] [CrossRef] [Scilit]

| Type | Strength | Scenes | Limitations | Reference |
|---|---|---|---|---|
| Euler–Bernoulli Beam | Linearized and analytical | Small-deflection magnetic beams | Neglecting shear and rotational inertia | [52] |
| Kirchhoff Rod | Coupled bending and torsion | High aspect-ratio slender fibers | Neglects shear and extension | [53] |
| Cosserat Rod | Full coupling (shear, torsion, extension) | 3D large-deformation soft robots | Highly non-linear equations | [54] |
| Type | Components | Characteristic | Advantages | Applications | Reference |
|---|---|---|---|---|---|
| Permanent magnets | Bulk magnets, robotic arms/motorized stages | High gradient, non-uniform fields | High energy density, zero power consumption, simple architecture. | Large-workspace navigation, deep-tissue intervention. | [70] |
| Magnetic coils | Coil arrays (Helmholtz/Maxwell) | Uniform, rotating, or oscillating fields | Rapid dynamic response, high precision, multi-field coupling. | Microrobot manipulation, precision vascular intervention. | [71] |
| Hybrid platforms | Integrated arrays, imaging feedback | Programmable composite fields | High integration, clinical compatibility, and superior robustness. | Clinical ablation, cardiac interventional surgery. | [72] |
| Type | Primary Function | Key Advantage | Current Limitation | Reference |
|---|---|---|---|---|
| Guiding/steering MCRs | Distal steering in tortuous vessels and lumens | Clinical-tool compatibility and active tip deflection | Limited force sensing, payload integration, and feedback | [134] |
| Variable stiffness MCRs | Switching between compliant insertion and stable operation | Tunable compliance for safer and more stable intervention | Slow stiffness switching, miniaturization constraints | [135] |
| Multimodal motion MCRs | Crawling, rolling, swimming, or helical locomotion in confined spaces. | Multiple motion modes and high environmental adaptability | Complex magnetization/control and unstable mode switching | [136] |
| Bio-inspired/biotemplated MCRs | Microscale propulsion, delivery, and manipulation in fluids | Efficient propulsion in low-Reynolds-number environments | Limited reproducibility, in vivo validation, and translation | [137] |
Disclaimer/Publisher’s Note: The statements, opinions and data contained in all publications are solely those of the individual author(s) and contributor(s) and not of MDPI and/or the editor(s). MDPI and/or the editor(s) disclaim responsibility for any injury to people or property resulting from any ideas, methods, instructions or products referred to in the content. |
© 2026 by the authors. Licensee MDPI, Basel, Switzerland. This article is an open access article distributed under the terms and conditions of the Creative Commons Attribution (CC BY) license.
Share and Cite
Zhang, M.; Song, L.; Yu, W.; An, X.; Ren, S.; Zhang, J.; Wang, S.; Li, J.; Li, J.; Li, Y.; et al. A Review of Magnetically Controlled Continuum Robots: Principles, Classification, and Applications. Magnetochemistry 2026, 12, 66. https://doi.org/10.3390/magnetochemistry12060066
Zhang M, Song L, Yu W, An X, Ren S, Zhang J, Wang S, Li J, Li J, Li Y, et al. A Review of Magnetically Controlled Continuum Robots: Principles, Classification, and Applications. Magnetochemistry. 2026; 12(6):66. https://doi.org/10.3390/magnetochemistry12060066
Chicago/Turabian StyleZhang, Mengyu, Liansheng Song, Wei Yu, Xindi An, Shuai Ren, Jiongzheng Zhang, Shuaida Wang, Jiefei Li, Junyang Li, Ying Li, and et al. 2026. "A Review of Magnetically Controlled Continuum Robots: Principles, Classification, and Applications" Magnetochemistry 12, no. 6: 66. https://doi.org/10.3390/magnetochemistry12060066
APA StyleZhang, M., Song, L., Yu, W., An, X., Ren, S., Zhang, J., Wang, S., Li, J., Li, J., Li, Y., Li, J., & Liao, P. (2026). A Review of Magnetically Controlled Continuum Robots: Principles, Classification, and Applications. Magnetochemistry, 12(6), 66. https://doi.org/10.3390/magnetochemistry12060066