Article

Increasing Efficiency of Chemico-Technological Systems and Prevention of Accidents: Approaches, Models, Portfolios


by
Gregory Yablonsky
1 and
Alexander Fedorov
2,*
1
Department of Energy, Environmental and Chemical Engineering, McKelvey School of Engineering, Washington University in St. Louis, St. Louis, MO 63103, USA
2
Scientific-Technical Centre for Innovations, INTER-Essen e.V., 45138 Essen, Germany
*
Author to whom correspondence should be addressed.
Processes 2026, 14(3), 524; https://doi.org/10.3390/pr14030524
Submission received: 25 December 2025 / Revised: 19 January 2026 / Accepted: 26 January 2026 / Published: 2 February 2026

Abstract

The aim of this work is to develop a beneficial methodology for improving the ecological and economic efficiency of chemico-technological systems (CTS). The problem is formulated as a control with a vector objective function that includes economic and environmental components. A practical approach to enhancing the environmental and economic efficiency of CTS is presented. Some approaches to accident prevention including the application of a problem-oriented dynamic model are introduced. Extended Ecological–Technological Portfolios have been developed. These Portfolios represent simplified visual models aiming to increase the environmental and economic efficiency of the CTS. Portfolios allow for the identification of dependencies between technological faults and ecological criteria and enable the investigation of the impact of the concrete chemico-technological process on the environment. Based on the Portfolios, decisions can be made for improving the economic–ecological efficiency of CTS and the prevention of accidents. Ecological–Technological Matrices, which provide a generalized characterization of technological breakdowns, have been developed. A strategy for adjusting technological constraints, using Matrices and vector criteria, has been proposed. Portfolios and Matrices can be applied in data preparation to solve certain artificial intelligence tasks for increasing the environmental and economic efficiency of potentially hazardous CTS. Some examples are given, presenting the industrial control of ammonia synthesis, methane conversion, and chemical absorption of CO2.

  • Hit two targets with one arrow!

1. Introduction

Ensuring the environmental and economic efficiency of chemico-technological systems (CTS) is among the most pressing challenges in modern chemical technology [1,2,3,4,5,6,7,8,9], and the solution to this problem has received significant attention in the literature. In [10], general environmental concepts and organizational measures are integrated into the production planning and control process at the management level to increase enterprises’ economic efficiency and reduce their environmental impact. In [11], the interdisciplinary nature of the problem is emphasized.
Achieving high environmental and economic efficiency (eco-efficiency) is associated with the concept of sustainable development. In [12], methods are proposed for assessing the sustainability factor, particularly through life cycle analyses and the preparation of eco-balances. In [13], measures and strategies to promote sustainable development in the chemical industry are outlined, emphasizing the importance of optimizing technological processes for more efficient resource use. In [14,15], the fundamental prerequisites for analyzing the environmental and economic efficiency of products and processes are provided. In [15], a method is presented for comparing different products or processes. This helps to establish which alternative is best from both an economic and environmental perspective.
In the literature [4,5,6,7], various definitions of environmental and economic efficiency have been proposed (Table 1).
Also, some general recommendations for eco-efficiency have been formulated [8]:
  • Integrating the principle of “sustainable development” into all business plans and activities;
  • Monitoring the environmental impacts at every stage of production; achieving multiple benefits with the least possible use of resources.
The analysis of the definitions mentioned shows the following:
  • All definitions are relevant, reflecting the different aspects of the problem;
  • There is a dramatic discrepancy among the definitions;
  • Definitions 3 and 4 do not concretely assess eco-efficiency.
This can be explained by both the complex and interdisciplinary nature of the problem, and by different goals—economic and environmental—that are formulated as well.
Achieving a high level of eco-efficiency is accomplished by solving a number of complementary tasks related to plant design and operation, safety engineering, personnel training, and so on. Our work is dedicated to improving the environmental and economic efficiency of CTS through multi-criteria control that includes accident prevention.
The achievement of high environmental and economic efficiency is understood as a beneficial improvement in the efficiency of CTS control, considering both economic and environmental objectives.
Our definition “efficiency via control” is also not rigorous; however, it can be considered as a guideline for practical achievements.
Potentially, chemico-technological processes can be highly hazardous. Accidents in chemical plants result in significant economic and environmental damage and reduce the efficiency of CTS substantially.
By “accidents”, we mean unplanned incidents associated with significant economic and/or environmental losses [1]. We also classify unplanned production shutdowns as accidents, as they result in prolonged equipment downtime and substantial economic losses.
Ensuring high eco-efficiency is closely connected with the avoidance of accidents.
In [1], a number of accidents at leading chemical enterprises in Europe, America, and Asia were presented and analyzed. “Accidents in the chemical industry occur rather frequently, despite the efficient equipment, modern control instruments, and regular safety measures.” [1]. In many cases, the losses caused by accidents are irreversible, and their consequences are unpredictable [1,9,16,17,18].
In [1], the methodology for accident prevention in the control of CTS, referred to as the Rational Control Methodology, is presented. Within this methodology, critical situations, emergency and pre-emergency, are distinguished.
An emergency situation is defined as a situation which corresponds to dangerous technological breakdowns. The term “dangerous” means that this situation will be followed by an accident if the appropriate and urgent control measures are not taken.
Pre-emergency situations are characterized by breakdowns which can lead to emergency situations in the absence of proper control measures. By direct detection of pre-emergency situations and analyzing the dynamic behavior, it is possible to predict emergency situations. Then, accident prevention is achieved through the recognition, prevention, and elimination of critical situations.
The possibility of accidents is linked to the concept of chemical risk, which receives considerable attention in the literature [3,19,20,21,22,23]. There are three trends in the risk assessment for chemical processes:
  • Rough risk assessment for chemical processes;
  • The search for new approaches to identifying potential hazards;
  • The justified development of strategies for accident-free control of complex technological processes [1,3,21,22,24].
The difficulty of improving the environmental and economic efficiency of CTS is caused by the following:
  • Chemico-technological processes are complex and multidimensional. They are nonlinear control objects with many strong feedbacks [1,25,26];
  • The problem is characterized by the general uncertainty;
  • Control objectives and control strategies in the normal operating mode and in critical situations can differ significantly [1,9];
  • Errors in measurements and calculations can lead to dramatic changes in chemical processes [1,25,26,27];
  • A large number of controlled variables (including interdependent quantities) creates difficulties for making the right decision within the limited time required to eliminate technological disruptions;
  • The number of controlled variables can be greater than the number of actual control actions [1,9];
  • A combination of various critical situations is possible, which complicates the prevention of accidents [1].
Control tasks in chemical plants are characterized by three types of uncertainty:
  • Uncertainty of goals caused by having several control objectives;
  • Uncertainty in the characteristics of technological processes determined by the complexity of measuring certain parameters and changes in the characteristics of the control object, as in the following examples:
    The catalyst activity is decreased due to the catalyst aging;
    In emergency situations, the characteristics of the object can change almost instantly [1,25,26];
  • Uncertainty of the operator actions: in automated systems, a number of control actions calculated by a computer are realized manually.
The task of improving the efficiency of CTS is associated with the mathematical modeling of chemical processes, which describes complex physico-chemical phenomena. Developing a comprehensive model of the technological control object that accounts for its environmental impact presents significant challenges. In some cases, a complete mathematical model of the control object is absent, and, moreover, its development is problematic.
The performed analysis of the literature demonstrates the topicality of praxis-oriented solutions for increasing the eco-efficiency of the CTS through control.
In our previous work [1], the Rational Control Methodology for improving the eco-efficiency via prevention and elimination of critical situations was created. This work [1] is used as the foundation for the conceptual framework of our current paper. At the same time, the direct application of the methodology [1] to a broad range of practical problems is possible, provided that additional constructive building blocks (approaches and models) are created.
The aim of the present work is to supplement and develop the methodology [1]. The enhanced methodology should be created considering the above-mentioned features of the real CTS and should be characterized as follows:
  • Setting of vector objective functions with ecological and economic components; practically overcoming the uncertainty of the control goals;
  • Beneficial accident prevention, which combines economic and ecological efficiency;
  • Practical considerations of the trends in the accident risk;
  • Development of approaches that ensure reliable stabilization of system parameters under rapid changes in the object characteristics over a wide range;
  • Ability to enhance the CTS efficiency via control, both with and without a complete mathematical model;
  • Development of Portfolio models for analysis and increasing the eco-efficiency of the CTS.

2. Materials and Methods

As a choice of global economic goal, profit, income, and return on investment are common; global ecological goals are basically formulated as resources and energy saving, effluent restriction, and risk restriction [9,28,29]. Economic and environmental goals may be in conflict, as taking environmental factors into account is often associated with additional costs or reduced profits (economic criteria). Resolving this conflict is one of the key tasks in the development and implementation of measures that incorporate environmental considerations.
While solving control tasks for increasing the eco-efficiency of a concrete CTS, we use a vector objective function (VOF) containing special economic and ecological components according to global economic and ecological goals:
R(X,U) = (Recon, 1(X,U),…, Recon, i(X,U),…, Recon, n(X,U), Recol, 1(X,U),…, Recol, j(X,U),…, Recol, m(X,U))
where X is the vector of input variables of the control object, U is the vector of control actions, Recon, i are scalar economic objective functions (i = 1,…, n), and Recol, j are scalar environmental objective functions (j = 1,…, m).
The objective function R(X,U) is developed considering global economic and environmental goals, as well as the specific characteristics of the control object. The ecological components of the VOF (1) reflect the influence of the CTS analyzed using the environment.
The task consists of minimizing and/or maximizing the scalar objective functions Recon, i and Recol, j (i = 1, …, n, j = 1, …, m) over the set of admissible solutions G. The given problem is a multi-objective (vector) optimization task.
Section 3.1 is based on the given problem formulation.
The presented vector objective function (1) must be specified for each CTS and coordinated with the global economic and ecological goals. This requirement is considered in Section 3.1 and Section 3.5. The function with structure (1) is used directly in Section 3.1. The components of this function are used in Section 3.3, Section 3.4 and Section 3.5.
The vector optimization task is characterized by the goal uncertainty. There is no universal method for solving the problem under consideration [30]. However, there are many well-known approaches to addressing this issue.
The approaches presented in [31] are mainly theoretical, which makes their practical application difficult. A number of problem-oriented approaches are presented in [30,32,33,34,35,36,37,38,39].
The difficulty in solving the multi-objective optimization problem lies in the fact that, for different objective functions, coordinates of the optima are generally different. The coincidence of economic and environmental criteria is an interesting case.
  • Examples of this include the following:
In ammonia produced from coke oven gas (ACG), the criterion of energy savings corresponds both to economic goals (maximizing profit by minimizing energy costs) and environmental goals (saving resources and energy).
When controlling the methane converter in ammonia production from natural gas (ANG) by supplying fuel gas, the economic criterion of minimizing natural gas consumption coincides with the environmental criterion for effluent restriction.
When developing strategies for overcoming goal uncertainty (Section 3.1 and Section 3.5), the possibility of this useful phenomenon was taken into account.
The technological description of ACG and ANG is provided in [1,35] and [1,40], respectively. Additional examples supporting these points can be found in Section 3.1.
Multi-objective optimization is brought to solving one or several single-objective optimization problems [30,32,33,34,35,36,37,38,39]. This principle is applied in Section 3.1 and Section 3.5 on the development of problem-oriented strategies for overcoming goal uncertainty.
The dilemma of ‘criterion vs. constraint’ often arises, which consists of deciding whether a scalar criterion will be directly used in the optimization procedure or converted into the corresponding constraint. In this case, the dimensionality of the objective function will be reduced. The first approach is more flexible and effective. However, the more components there are in the VOF, the more necessary it becomes to replace individual criteria with corresponding constraints.
Ultimately, accident-free operation of the CTS is achieved by complying with a set of technological constraints, which include requirements for technological regulations and, sometimes, additional calculated restrictions on the process parameters of the object and their functions [1]:
Z = {z1, z2,⋯, zk,⋯, zp}
N k     z k   H k
k   =   1 , ,   p
where Z—vector of controlled process parameters, zk—controlled process parameter (at specific values of k), Nk and Hk—lower and upper boundaries of the controlled parameter, k—index of the controlled parameter, p—number of controlled parameters.
Conditions (2)–(3) are used in Section 3.3, Section 3.4 and Section 3.5.
A practical approach to the vector optimization problem for improving the environmental and economic efficiency of the CTS is presented in Section 3.1.
In the control system, functional tasks are implemented at two levels: dynamic stabilization of technological parameters and static optimization (computation of optimal setpoints for stabilization systems). Typical methods of steady-state optimization are given, e.g., [34,36,41,42,43,44,45,46].
In optimizing the static mode, various mathematical models are used:
(A) Statistical steady-state models;
(B) Analytical steady-state models;
(C) Problem-oriented analytical–experimental steady-state models.
Type (A) models are constructed on the basis of experimental data using statistical methods [42,43,44,47]. Such models are typically represented by regression (algebraic) equations. Sometimes, neural networks are used [48], which essentially belong to statistical models. The application of models (A) is limited, which is explained both by the nonlinearity and multidimensionality of the CTS and by the need for a large amount of experimental data for developing such models.
In the practice of controlling static optimization, (B) and (C) models are predominantly used. Models of type (B) are developed based on the material and energy balances [43,44,49] considering the physical and chemical characteristics of the specific technological process. (C) models are combinations of simplified (B) models and (A) models. The structures of these models are constructed based on physical and chemical characteristics as well. The model coefficients are then determined from experimental data using statistical methods (parametric identification).
Models of types (B) and (C) can be represented by algebraic equations and/or differential equations containing derivatives with respect to spatial variables. For systems involving multiple spatial coordinates (distributed-parameter systems), partial differential equations are used. The number of coefficients determined in (C) models is significantly smaller than that for (A) regression equation models.
Stabilization tasks impose strict demands for dependability and rapid adaptation when an object’s characteristics undergo significant changes during critical situations. The development of appropriate mathematical models is essential for effectively addressing such challenges. Consequently, these models must satisfy specific requirements, defined as follows:
  • Reliability;
  • Ability for fast computation;
  • Simplicity of implementation;
  • Taking measurement errors into account;
  • Sufficient accuracy for solving the concrete task;
  • Low sensitivity to disturbances;
  • Capability for fast adaptation in critical situations.
As a rule, increasing the complexity of the model leads to a higher sensitivity to disturbances. [16,17,18].
The requirements (a)–(f) are practically identical to the real-time model requirements described in [16,17,18]. Requirement (g) constitutes a significant additional specification. Since there is a contradiction between some listed requirements, a reasonable compromise should be achieved for developing an acceptable model. Targeted study of the physical–chemical properties and specific features of the control object is a prerequisite for successful modeling. The approaches presented in Section 3.2 were developed considering these specific requirements.
Rigorous dynamic models of chemico-technological processes are highly complex, e.g., the rigorous model of a single CO2 chemical absorption column includes several thousands of nonlinear temporal–spatial partial differential equations. Computing a single transient process can take several hours or even days [16]. Such models cannot be used directly for real-time problem solving, especially in control systems aimed at preventing and eliminating critical situations.
Methods for developing simple linear typical experimental dynamic models for control applications are presented, for example, in [50,51]. Similar to steady-state models, analytical and problem-oriented analytico-experimental dynamic models also exist [16,17,18].
In practical stabilization tasks, it is often necessary to use approximate, problem-oriented dynamic models. As for the model’s accuracy, it should be sufficient to ensure the solution of the particular task under consideration.
The simplest method for developing problem-oriented dynamic models is the approximation of transient processes using simple standard differential equations with time-delay arguments or transfer functions. Transient processes are obtained via the experiment, real or computational using the rigorous model. Typically, such problem-oriented models describe the technological process within small deviations from the equilibrium state. Examples of these models are provided in [17,18]. The development of grey-box models is significantly much more effective. Simplified mass and energy balances are used, as well as approximate models of chemical kinetics. The obtained model, then, is refined either based on experimental data or through comparison with the rigorous model.
  • An example of this is as follows:
In [16], the development of a grey-box model for the process of CO2 chemical absorption is presented. Using this model, the computation time of the transient process takes approximately 2 s, not hours or days.
The implementation of dynamic stabilization systems reduces the risk of accidents. In Section 3.2, some approaches to improving the reliability of such systems are presented. Also, the rational problem-oriented model is described.
When implementing control strategies in operating industrial units, it is important to consider practical difficulties related to the specific characteristics of the concrete process, the following in particular:
  • Measurement errors of technological variables;
  • Errors in the realization of control actions;
  • Possible actuators’ failures [1,9];
  • Uncertainty of the operator actions (see Section 1).

3. Results

3.1. Approach to Improving the Ecological and Economic Efficiency of the CTS

This section presents a new approach we have developed for improving the environmental and economic efficiency of chemical–technological systems (CTS), including accident prevention. This approach represents a further development of our previous approach for the prevention and elimination of critical situations presented in a previous paper [1].
A key element of the approach is a new strategy for overcoming uncertainty in control objectives.
Two or more of the most important objectives—up to four in total—are selected. Among the selected objectives, an accident risk objective and at least one economic objective must always be included. If three objectives are selected for the CTS, they might, for example, include the following:
(1)
Minimizing the risk;
(2)
Maximizing the output of the main product;
(3)
Minimizing the costs.
Realizing these goals supports the achievement of the corresponding global goals. In this case, the economic objective (3) coincides with the global environmental goal of resources and energy saving. The remaining objectives are considered as additional constraints.
The simplified multi-criteria objective function is
R(X,U) = (P(X,U), L(X,U), A(X,U))
where P, L, and A are the output of the main product, the costs, and the risk of accidents, respectively.
The formulated task is a maximization of the productivity P and the minimization of costs L and risk A:
P X , U min     ( P X , U max ) L X , U min                                                             A X , U min                                                             U Ω
where Ω is the set of admissible solutions.
Technological constraints (2)–(3) are included in the overall system of constraints Ω .
Considering the complexity of risk estimation, we focus on minimizing the risk of accidents by solving three complementary tasks presented in [1]: prevention, recognition, and elimination of critical situations. In light of these tasks, problems (4)–(5) are replaced by the following set of tasks (Figure 1):
(a)
Optimization of the CTS based on productivity and cost criteria;
(b)
Recognition of critical situations and normal operating mode;
(c)
Elimination of detected critical situations, which are observed in the operating unit;
(d)
Realization of complementary subtasks (procedures) in solving tasks (a)–(c), aimed at preventing critical situations and increasing the reliability and survivability of the system.
A normal operating mode is understood as the mode of the object under steady-state conditions with no critical situations.
Task (a) is a multi-criteria optimization problem. This task is carried out only in the normal operating mode. To overcome the uncertainty of control objectives, the priority principle [31,33,35] is applied, whereby maximizing productivity is given higher priority than minimizing costs:
P ( X , U )     L ( X , U ) .
Cost minimization is performed under the condition that the productivity must not decrease by more than the allowable amount for this criterion (in some cases, this amount may be zero).
The implementation of task (a) must not increase the risk of accidents as a result of the optimization. This is ensured by considering the technological constraints for the normal operating mode of the CTS. Within these constraints, the risk either does not change at all or changes by only a negligible amount.
In solving task (a), there may be cases where an increase in the productivity of the technological process also leads to a decrease in costs.
  • Example 1.
In ammonia production (ACG), optimizing the temperature regime of the ammonia synthesis reactor according to the productivity criterion and using cold bypass leads both to productivity increases and energy savings. At the same time, reliable operation of the reactor is also guaranteed since the optimal regime is always stable.
  • Example 2.
Optimizing the hydrogen-to-nitrogen ratio in the input mixture at the inlet of the synthesis reactor used for ammonia production (ANG or ACG) leads both to the productivity increase of the reactor and energy savings.
Tasks (b)–(d) as well as their corresponding subtasks are described in [1,52]. The task of recognizing critical situations also includes recognition of the normal operating mode.
The implementation of tasks (b)–(d) significantly reduces the risk of accidents while having virtually no negative impact on the other components of the criterion R(X,U).
Some examples of complementary subtasks (procedures) for preventing critical situations are taken from our previous publications [1,52]:
  • Logico-technological verification of the input data and the computed control actions;
  • Approximate estimation of unreliable process parameters;
  • Using simplified control algorithms when some process parameters are unreliable;
  • Prediction and analysis of key process parameters, such as temperature, pressure, and concentration;
  • Dynamic stabilization of controlled parameters under rapid and significant changes in the object characteristics, especially during critical situations;
  • Checking the realization of control actions in each control step.
The essential subtasks for preventing critical situations also include the following:
  • Calculation of variable constraints on process parameters depending on input parameters and/or the actual state of the technological object;
  • Monitoring the technological process state;
  • Monitoring the operator performance (assessment of operator efficiency).
Within task (b), the additional procedures for assessing the condition of the technological equipment are as follows:
  • Fault detection and diagnosis of technological equipment;
  • Catalyst state diagnosis.
At the development stage of the systems, some solutions for preventing critical situations, particularly those aimed at improving the system reliability, survivability, and control quality, are applied, for example, the following:
  • Organization of autonomous control for the subsystems of the technological object [1];
  • Application of combined control methods for creating fast and robust control systems (see Section 3.2.4);
  • Application of the Anti-Windup technique [53,54];
  • Ensuring shock-free switching the control systems;
  • Realization of considered tasks based on the modular principle.
Tasks (b) and (d) are carried out in all operating modes of the CTS. In critical situations, control is based solely on the risk minimization criterion, with the aim of eliminating hazardous technological disturbances.
In the present approach, when implementing the static optimization task within the given technological constraints, the risk of accidents does not increase. In the normal operating mode, the tasks of prevention and recognition of critical situations significantly reduce the risk of accidents without worsening productivity and cost criteria. Moreover, in some cases, the reduction in risk is accompanied by increased productivity and/or decreased costs.
Thus, the implementation of the four aforementioned tasks leads to an increase in the economic and environmental efficiency of CTS.

3.2. Some Approaches to Improving the Efficiency of Stabilization Systems for Accident Prevention

3.2.1. Rational Dynamic Modeling of Control Object

In this section, an approach for the development of mathematical models for dynamic stabilization tasks is given. This approach represents a further development and generalization of previous approaches presented in our other publications [1,9].
In the case considered, the control object is subsystem 1 of the CTS, the input of which is the vector X e , the control vector is U e , the output variable is y e , and the disturbance is denoted by ze.
The approach is presented based on the generalized deviation model with the following structure:
T e y e ˙ + N y e = k 1 u e , 1 t T t , 1 + + k l u e , l t T t , l + + k λ u e , λ t T t , λ + + d 1 x e , 1 t τ 1 + + d s x e , s t τ s + + d µ x e , µ t τ µ + z e ( t )
k l = Ψ 1 , l X e ,     d s = Ψ 2 , s X e ,       T t , l = Ψ 3 , l X e ,   τ s = Ψ 4 , s X e
T e = Ψ 5 X e
N = 0   o r   1
X e = x e , 1 , , x e , s , , x e , µ
U e = u e , 1 , , u e , l , , u e , λ
where T e is the time constant, N ,   k l , d s are the corresponding coefficients, t is time, T t , l   ,   τ s are the dead time, and u e , l and x e , s are the control actions and the input variables ( l = 1 , ,   λ , s = 1 , , µ ) .
The model with structures (7)–(8) and variable parameters can correspond to many real and potentially hazardous processes including both stable ones and those that may lose stability in critical situations. Such a model is fast and easily adjusted in the case of significant and quick changes in system characteristics, especially during critical situations.
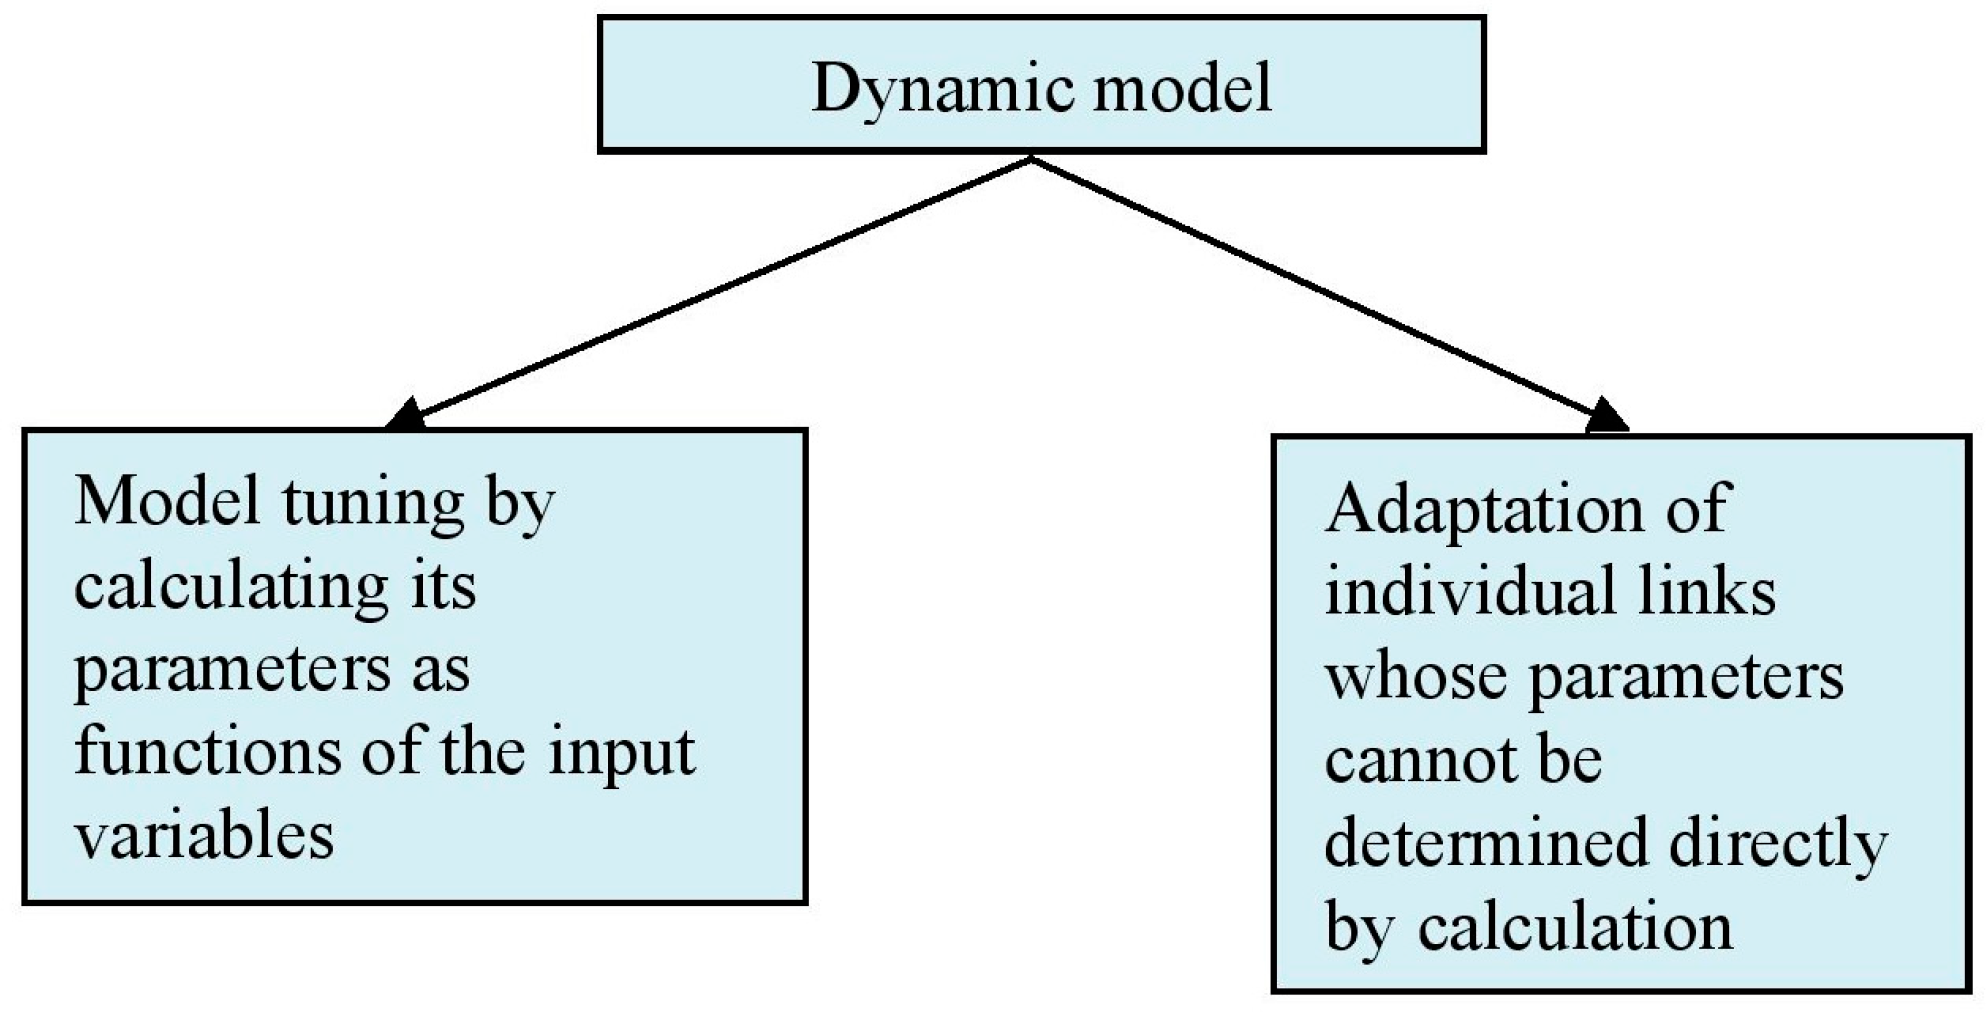
In some cases, when it is not possible to find the required dependencies to adjust all parameters, the model can be decomposed into simpler blocks. The goal of such decomposition is to accelerate the adaptation of a dynamic model in real time. Within this decomposition, two blocks are distinguished (Figure 2). In the first model block, the fast adjustment of parameters occurs according to the approach described above. The second block reflects those processes whose model parameters cannot be directly calculated as functions of input vector X f . Such parameters are adapted, for example, by minimizing the deviation of measured data from calculated data. In the ideal case, non-inertial links (gain elements) of the second block should be adapted.
Example: Control of the maximum temperature in the reaction zone of an autothermal reactor, based on the simplified deviation model:
T y u ˙ + y u = k g u t T t   + z u ( t )
where y u is the maximum temperature in the reaction zone, u is the position of the gas supply valve into the reaction zone, T is the time constant, k g is the gain parameter, T t is the dead time, and z u is the disturbance.
Model (9) is decomposed into two blocks:
T y f ˙ + y f = c u t T t   + z u ( t )
y u = β y f
where y f is the mean temperature in the reaction zone, c is the gain parameter, and β —is the adaptive coefficient.
For the model parameters,
c = φ 1 X f ,     T = φ 2 X f ,   T t = φ 3 X f   ,   β c = k g
In the first model block (10), the parameters c , T , and T t are calculated depending on the components of the vector X f . In the second block (11), the parameter β is adapted using the measured values of y f , and y u . Here, the parameter β can be directly calculated as β =   y u / y f   , followed by smoothing.
The essence of approaches considered in this section lies in ensuring the almost instantaneous estimation of the dynamic characteristics of the CTS, which in critical situations can change extremely quickly.

3.2.2. Consecutive Emergency Control

In this section, an approach for preventing and eliminating critical situations by realizing dynamic stabilization tasks is given. This approach represents a further development of our previous approach given in previous publications [1,9].
The following presents the developed approach.
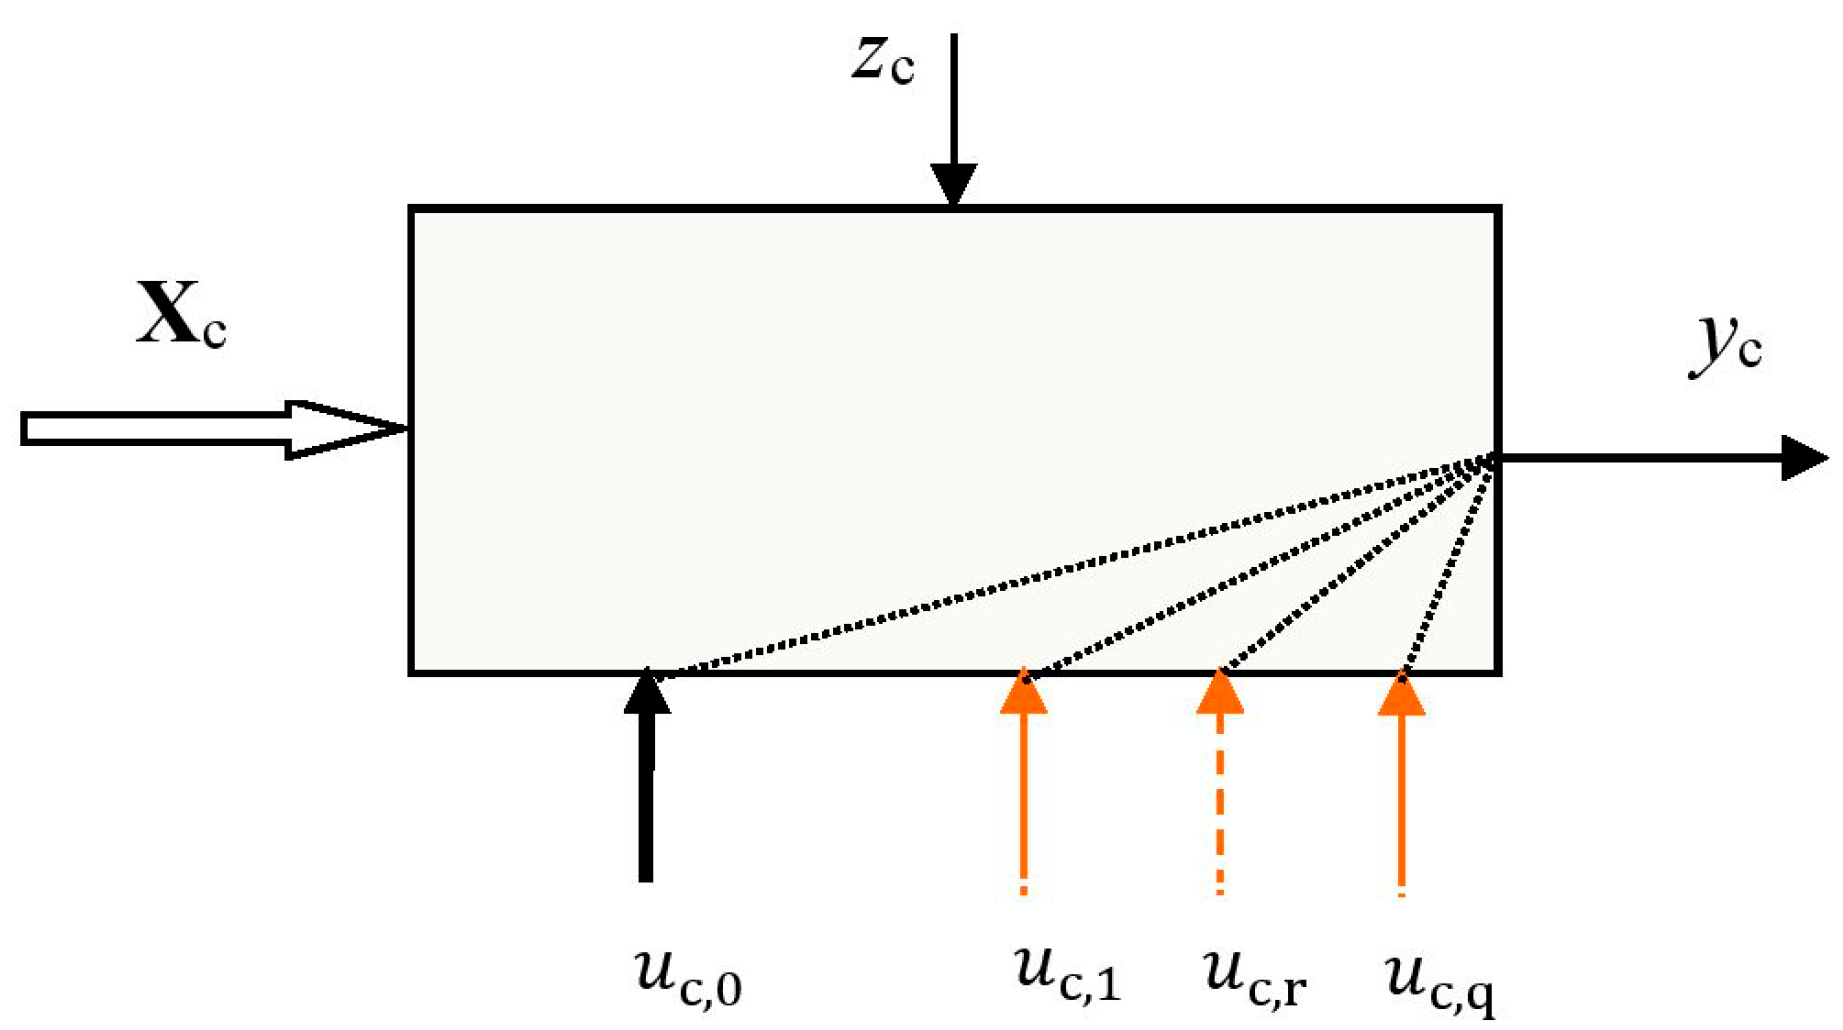
The considered control object (Figure 3) is subsystem 2 of the CTS, whose input is the vector X c , control is the vector U c , controlled variable is y c , and disturbance is zc. For preventing and eliminating critical situations, auxiliary autonomous control loops are introduced in addition to the main control loop with the control action u c , 0 [9].
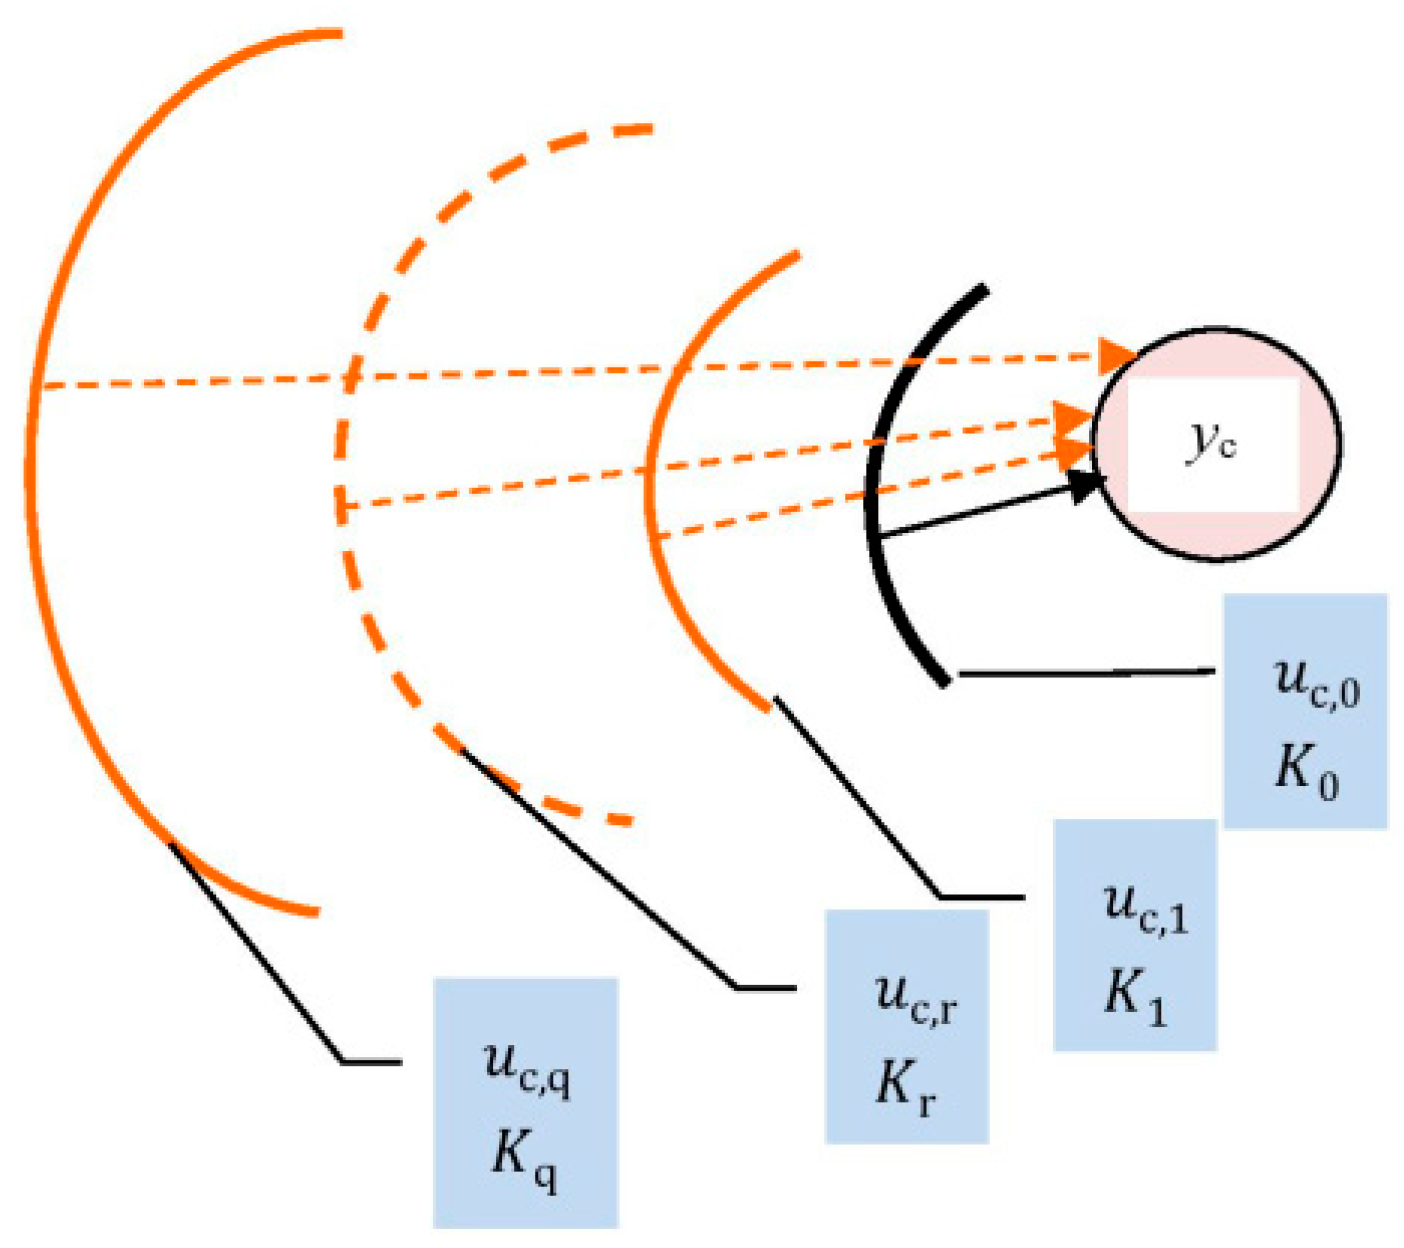
The auxiliary loops operate independently of the main loop. They are activated when the controlled variable deviates dangerously from its setpoint and the use of the corresponding control action is permissible. Here, the admissibility of control means that the control action must not lead to another critical situation or aggravate a dangerous one, which exists already. The sequence Ψ , in which the auxiliary loops are engaged, corresponds to the cost incurred by the respective control actions (Figure 3 and Figure 4):
Ψ :   u c , 1 ,   u c , 2 ,   ,   u c , r , , u c , q                       K 0 <   K 1 < K 2 , <   K r < K q  
U c = u c , 0 , , u c , r , , u c , q
where U c —the control vector, u c , r —the control action in the corresponding control loop, r—the index of control action in the corresponding control loop, and   r = 0 ,   ,   q , Kr—the specific cost associated with the r-th control used to eliminate the critical situation.
In accordance with the presented approach, in many cases, models with structures (7)–(8) can be used in the development of stabilization systems.

3.2.3. Modeling: Variations of Parameter Ranges

Sometimes, the structure of a dynamic model is known but equations for parameter calculation are absent. In this case, it is useful to derive relationships that express ranges of parameter variation in terms of the input variables (vector X f ) and/or the catalyst state. Often, such relationships can be used to control for improving the system performance under critical situations.

3.2.4. Combined Compensation of Changes in the Control Object’s Characteristics

This approach integrates approaches in Section 3.2.1 and Section 3.2.2 with control techniques that support the development of fast and robust controllers. Some controllers and their applications in combination with previous simpler approaches (3.2.1) are presented, for example, in our previous publications [1,9,24].

3.3. Extended Ecology–Technological Portfolios

In this section, we present the Portfolio models, which link the ecological criteria and technological faults.
In a number of cases related to ensuring accident-free operation, it is necessary to identify parameters, measured or calculated, whose violation leads to a significant increase in the accident risk. Subsequently, constraints on such parameters are considered in the prevention and elimination of critical situations. Sometimes, it becomes necessary to adjust the constraints previously used.
Often, there is a need for monitoring the relationship between technological faults that may occur during the operation of the object and the changes in environmental criteria. Also, the task of analyzing the long-term environmental consequences as a result of technological faults arises.
In many cases, obtaining the accurate mathematical model for calculating the required environmental criteria is either impossible or presents significant challenges. Moreover, the environmental criteria are often difficult to express in precise numerical values.
To solve the tasks outlined above, simplified models that describe the influence of technological parameters on the ecological criteria are needed.
In economics, the methodology of developing ecology–economic Portfolios has demonstrated effectiveness [28,55]. This methodology makes it possible to find a strategy for actions depending on the ecological and economic situation. The so-called ecological–technological Portfolio is commonly used in the analysis of Social–Ecological–Technological Systems (SETS) [56]. These Portfolios refer to collections of technologies designed to minimize environmental impact while maintaining functionality and performance. They often prioritize efficiency, sustainability, and the use of environmentally friendly materials.
One example is socio-hydrological modeling of flood-risk dynamics, which allows for comparing the resilience of different systems [57]. Other examples include high-voltage solutions that use air instead of SF6 gas for insulation, which reduces the global warming potential of the gas but may require additional equipment [58].
Sometimes, Portfolios are used for modeling the technological uncertainty and innovation risk [59]. When using Portfolios, decision-making can be supported by multi-criteria optimization methods [60].
Considering the Portfolio methodology, we developed Extended Ecological–Technological Portfolios (EETPs) aimed at analyzing and controlling potentially hazardous CTS. EETPs enable the identification of dependencies between environmental criteria and technological faults considering the uncertainty of the chemico-technological object and its environmental impact. Based on these dependencies, decisions regarding various problems related to the assessment and increase in CTS eco-efficiency, including accident prevention, can be made.
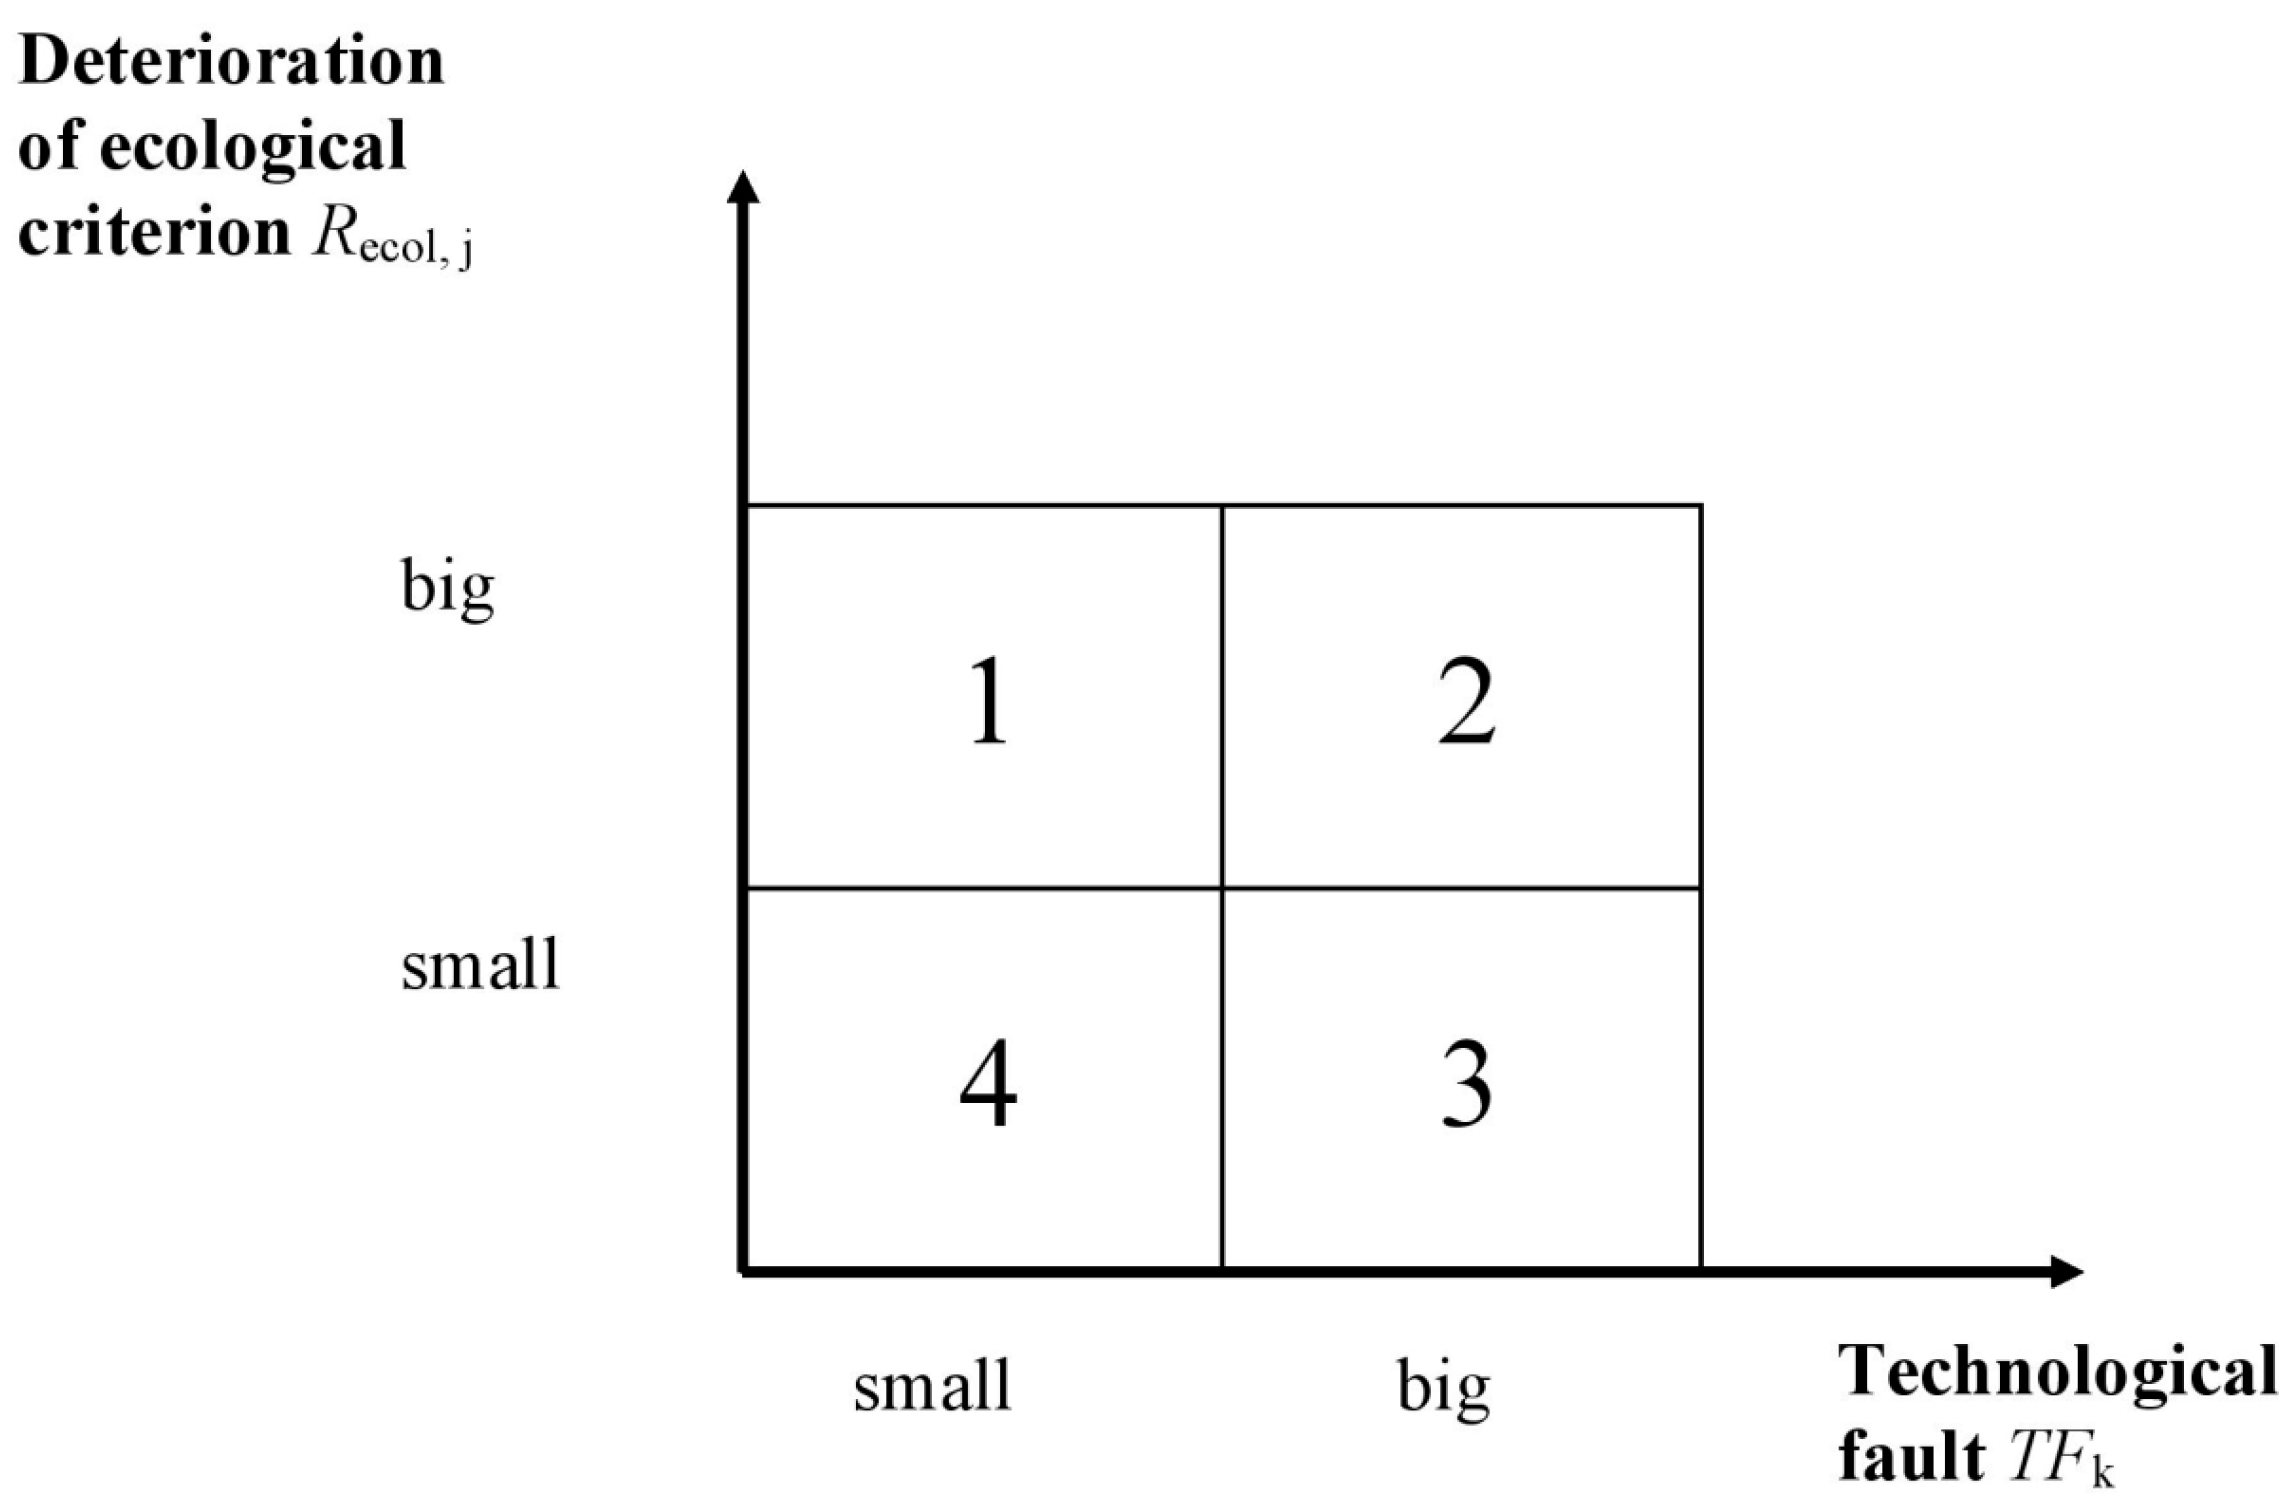
In one EETP (Type 1, Figure 5), the technological faults (TFk) and the deterioration of the ecological criterion (Recol, j) are the coordinates used as the axis of abscissae and the axis of ordinates, respectively. Based on the qualitative classification, four cases are distinguished:
  • Small TFk, big Recol, j;
  • Big TFk, big Recol, j;
  • Big TFk, small Recol, j;
  • Small TFk, small Recol, j.
From the ecological perspective, Case 1 is the most hazardous. If the technological parameter corresponds to this case, strict actions are needed to prevent technological faults, even if they are small. As an example, the loss of thermal stability of the autothermal reactor in ammonia synthesis can be considered [1]. This can lead to emergency shutdown and air pollution by effluents (coke-oven gas and/or products of its combustion). Case 3 is the least dangerous, e.g., in ammonia production from natural gas, an increase in steam surplus in steam/gas ratio control cannot result in considerable ecological consequences.
As technological faults, violations of both parametric limits and parametric functions can be considered. Dangerously exceeding the temperature rate is an example of such a violation.
The dependence of any ecological criterion on a technological fault can be determined for appointed conditions that can be defined with the help of a set of technological parameters and restrictions. The change in ecological criteria can be considered not only at one temporal point but also during the time interval. Every criterion can be supplied by different Portfolios, e.g., risk restriction, effluent restriction, etc. In the presence of two, upper and lower, constraints on the technological parameter or function, Portfolios are constructed considering the violations of both limits.
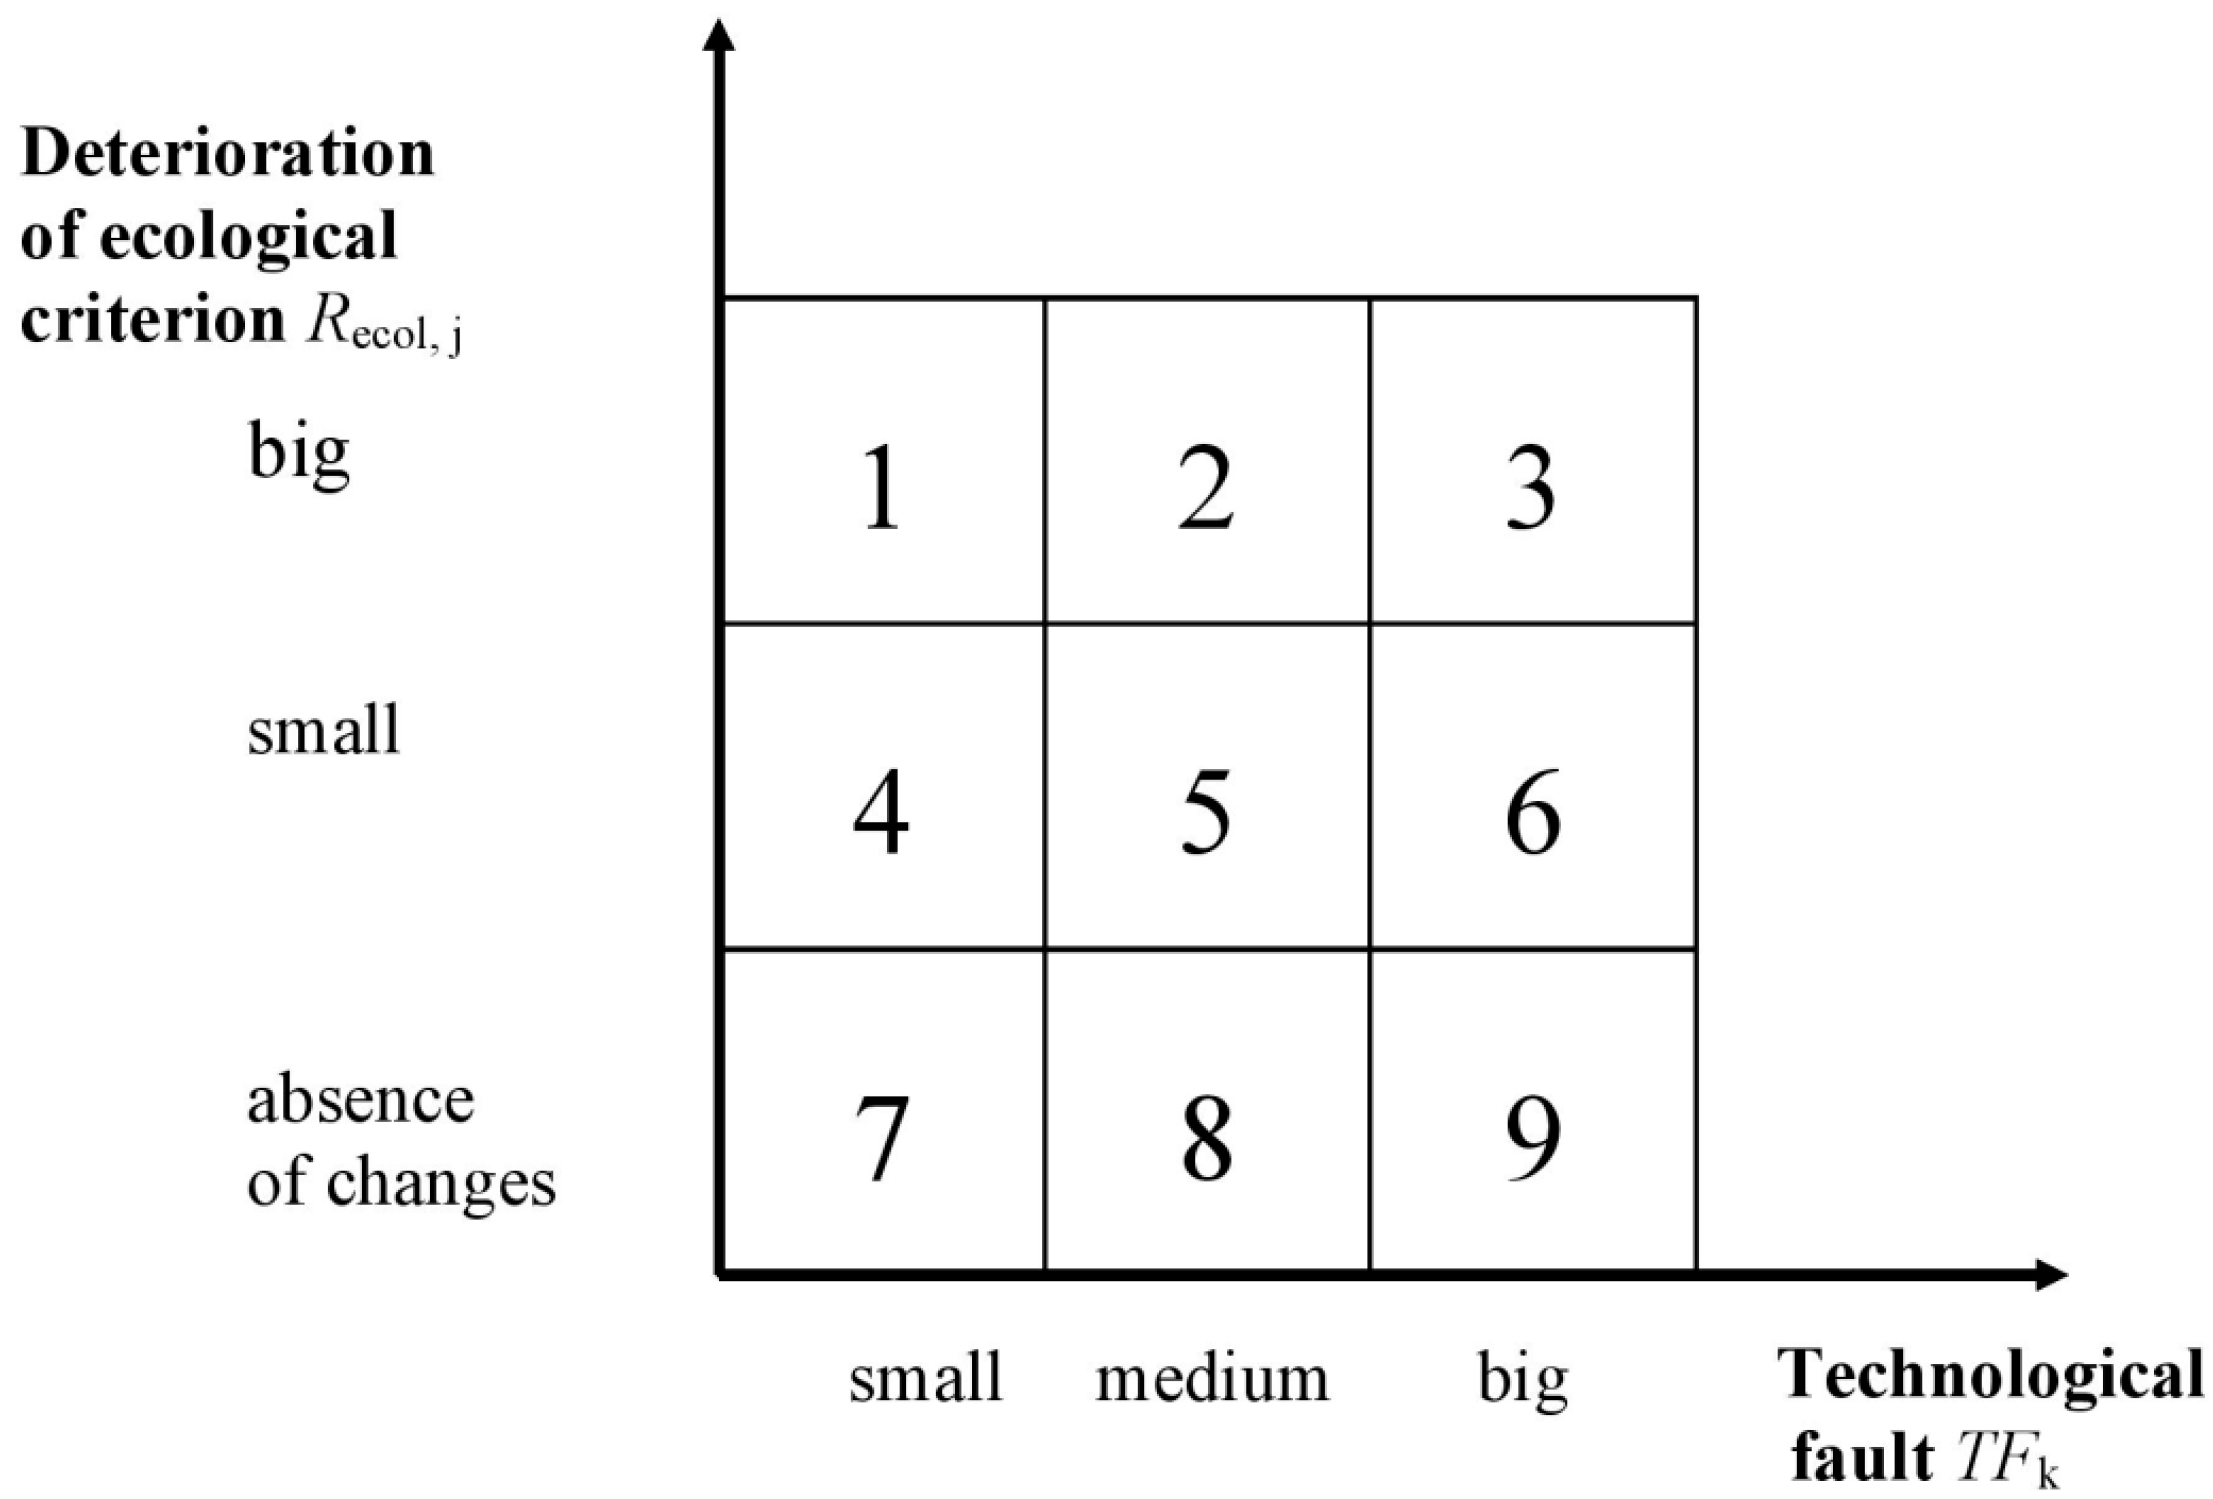
In our approach, different Portfolios are used, e.g., Portfolios in which, in addition, the changes of ecological criteria are absent (Type 2, Figure 6). Small, medium, and large faults are considered. The deterioration of the Recol, j criterion is categorized into three levels: absence of changes, small changes, and large changes.
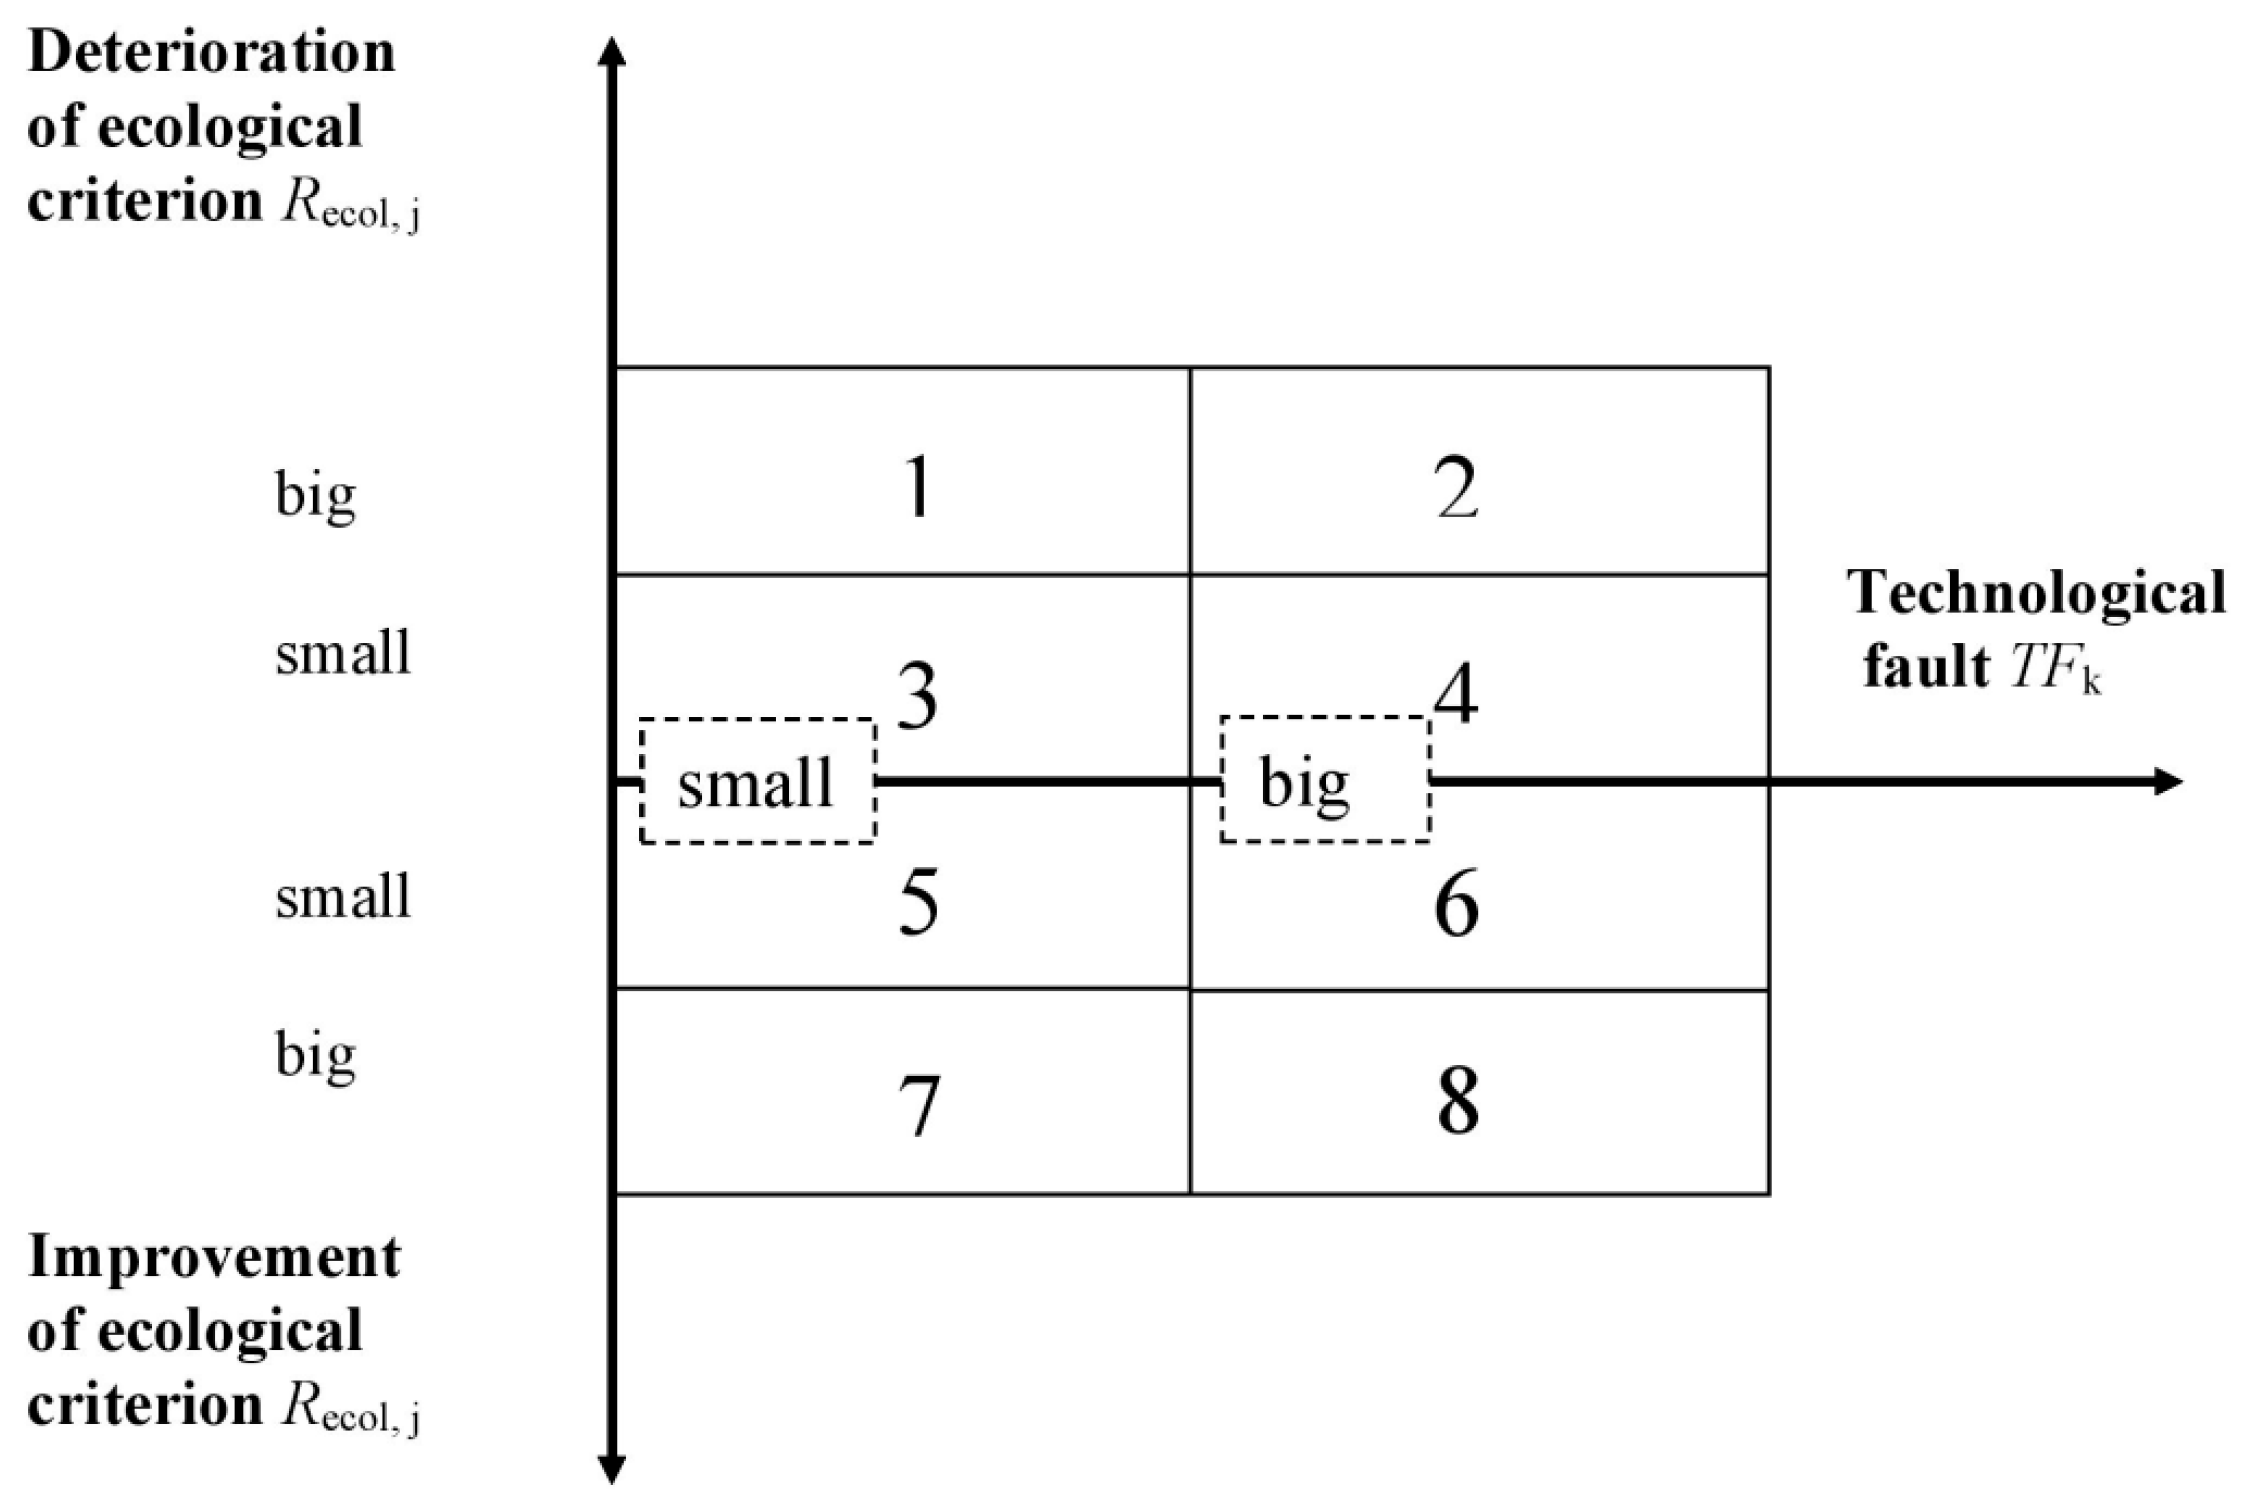
The Portfolio presented below, the ‘symmetrical’ Portfolio, allows us to characterize not only the deterioration but also the improvement of the Recol., j criterion as well (Type 3, Figure 7). Four cases correspondent to the deterioration of Recol., j and four cases correspondent to its improvement are located above and below the axis of the technological fault, respectively.
In Table 2, some results of analyzing typical chemico-technological processes using the developed Extended Ecology–Technological Portfolios are demonstrated.
As for the particular ecological criterion R e c o l , j , the following question arises: “Can it be improved by the narrowing the allowable range of a specific process parameter?” A necessary condition for such an improvement is the monotonic influence of the parameter z k on the criterion R e c o l , j .
In this case, by monotonic influence, we mean a decrease (increase) in parameter z k , resulting from a decrease (increase) in its upper bound Hk (lower bound Nk) by the amount Dk (Vk) leads to an improvement in the environmental criterion R e c o l , j across the full range of the Dk (Vk)—this is requirement M1 (M2).
If requirement M1 (M2) is satisfied, a decrease (an increase) in the upper limit Hk (the lower limit Nk) by the amount Dk (amount Vk) may be considered.
The existence of monotonic influence within the defined interval is determined via the analysis of the technological object. The concepts of ‘big’ or ‘small‘ faults as well as the values of Dk and Vk are specified for every technological process. In specifying these terms, we employ expert evaluation methods [61]. The input data for these methods are provided by operators, technologists, and/or process developers.
EETP can be complemented by Economic–Technological Portfolios (ETP), which reflect the influence of technological faults on the economic criteria. The axes of abscissae of both Portfolios, ETPs and EETPs, are identical. The axes of ordinates for ETPs and EETPs are changes in the economic and environmental criteria, respectively. EETPs and ETPs allow the realization of procedures that are useful for solving vector optimization problems:
  • Distinguishing the control actions that influence a specific criterion, and those that do not have a significant impact on it;
  • Finding overlap between the criteria;
  • Adjusting the technological constraints in accordance with environmental regulations and current market requirements;
  • Clarifying the selection of scalar objectives included in the multi-criteria objective function;
  • Acquisition of information for overcoming the uncertainty of control objectives.

3.4. Techno-Ecological Vectors and Techno-Ecological Matrices

Based on the Extended Ecology–Technological Portfolios, the Techno-Ecological Vectors (TEV) are constructed:
T k   =   [ ξ ,   a k , 1 ,   a k , 2 ,   a k , 3 ,   a k , 4 ,   b k , 1 ,   b k , 2 ,   b k , 3 ,   b k , 4 ]
Here, ξ is the index of the control action that causes a change in the parameter zk,; ak,1, bk,1—indications of the presence of lower and upper boundaries for the parameter zk (0—the constraint is absent, 1—the constraint is present); ak,2, bk,2,—the impact of a small violation from lower and upper boundaries on the risk criterion; ak,3, bk,3—the impact of a small violation of the lower and upper boundaries on the emissions criterion; ak,4, bk,4,—the impact of a small violation of the lower and upper boundaries on the cost criterion.
Values 0, 1, 2, and 3 for the indicators ak,2ak,4 and bk,2bk,4 represent different cases, i.e., no influence, weak influence, moderate influence, and strong influence, respectively. Symbols“−” and “+” correspond to the decrease and increase in the criterion, respectively.
The Techno-Ecological Vector reflects the changes in the environmental criteria which result from the change in the parameter zk, caused by the control action u ξ . This vector is used to compile the Techno-Ecological Matrix (TEM). The rows of the TEM consist of TEV vectors (14).
Table 3 presents the results of TEM development for several parameters in ammonia production. The change in index ξ from 1 to 4 characterizes the following control actions, respectively:
  • The nitrogen supply for H2/N2 ratio control;
  • The temperature change at the outlet of the ammonia vaporizer;
  • The liquid ammonia supply into the vaporizer;
  • Change in ‘cold’ bypass flow.
Techno-Ecological Vectors and the Techno-Ecological Matrix for medium and/or large constraint violations of the controlled parameters are also formed in a similar way.

3.5. Constraint Adjustment Strategy

The strategy for adjusting the technological constraints (SATC) is explained below.
The criteria being considered may include the risk of accidents, emissions, and costs (consumption of raw materials and energy). To solve the problem, a priority system is established. Within this priority, reducing the risk of accidents takes precedence over minimizing emissions, which in turn is prioritized over cost reductions:
A X , U     E X , U     L X , U
Restrictive conditions:
  • The potential decrease in productivity should not exceed the allowable amount d = d1 + d2 + d3, where d1, d2, d3 are the allowable reduction in productivity at each stage of optimization, respectively;
  • The potential increase in emissions E resulting from cost reductions L must not exceed the allowable value d4.
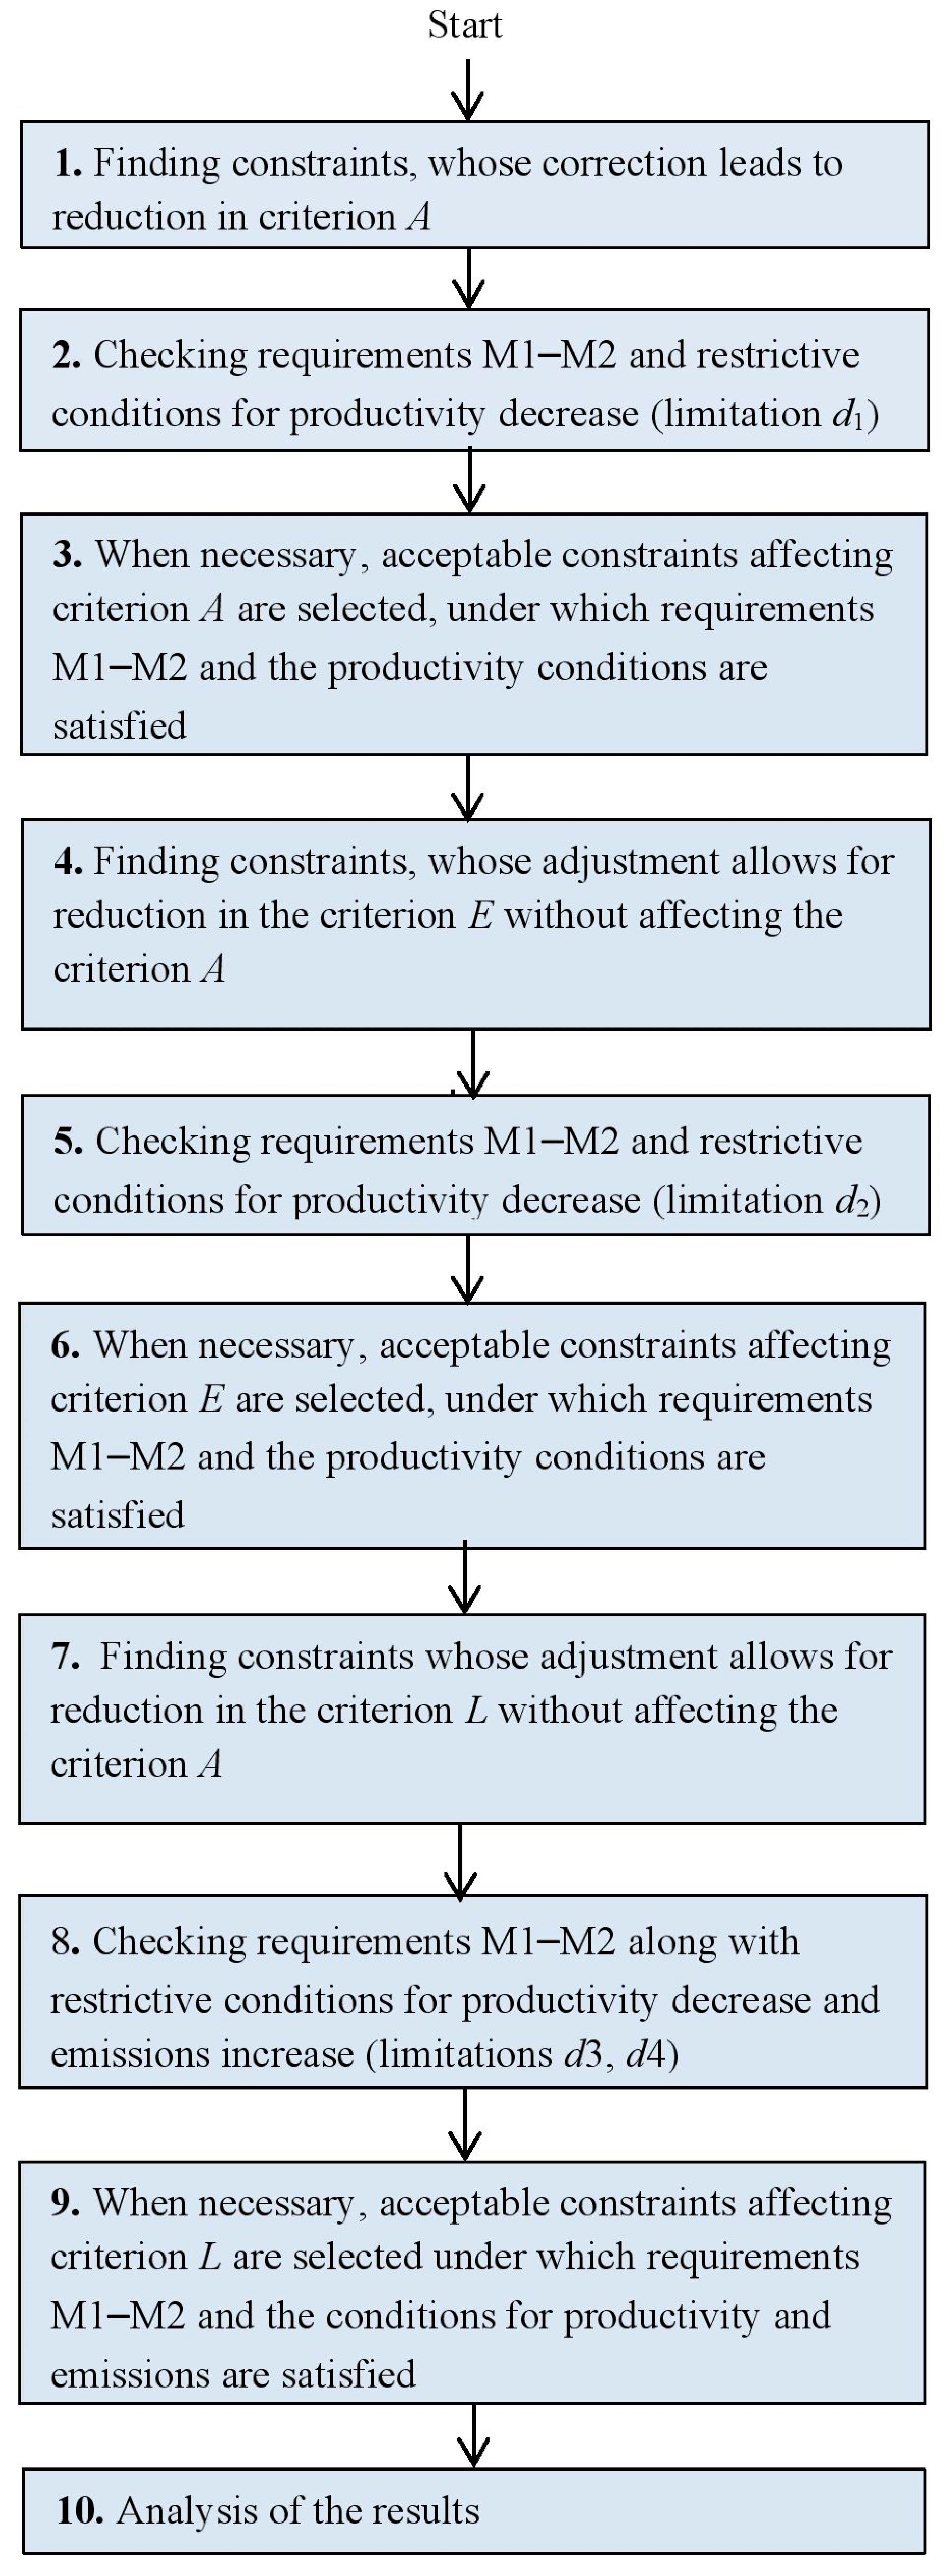
The strategy is illustrated in Figure 8.
Block 1.
Using the Techno-Ecological Matrix, the constraints are chosen which correction leads to reduction in the risk criterion.
Blocks 2–3.
The requirements M1–M2 regarding the monotonic influence of changes in associated parameters on the risk are checked. If these requirements are not met for certain parameters, the corresponding constraint adjustments are rejected.
The admissibility of the maximal possible reduction in the productivity, which results from risk minimization, is verified. If the total reduction in the productivity exceeds the specified value d1, acceptable constraints are selected. Under chosen constraints, the requirements for d1 must be satisfied, e.g., preference can be given to those constraints for which adjustment results in the biggest reduction in risk with the smallest decrease in productivity. If any suitable constraint cannot be found, minimizing the risk is abandoned.
Block 4.
In accordance with the Techno-Ecological Matrix, the constraints are chosen which adjustment allows for a reduction in the emissions criterion without affecting the risk criterion.
Blocks 5–6.
The requirements M1–M2 regarding the monotonic influence of changes in associated parameters on emissions are checked. If these requirements are not met for any parameters, the corresponding constraint adjustments are abandoned.
The admissibility of the maximal possible reduction in the productivity, which results from emissions minimization, is verified. If the total reduction in the productivity exceeds the specified value d2, acceptable constraints are selected. Under chosen constraints, the requirements for d2 must be satisfied, e.g., preference is given to the constraints for which adjustment results in the smallest reduction in productivity. If any suitable constraint cannot be found, minimizing the emissions is abandoned.
If necessary, after minimizing the risk and the emissions, the possibility of process optimization based on the minimum cost criterion is also considered.
Block 7.
In accordance with the Techno-Ecological Matrix, constraints are chosen which correction allows for a reduction in the cost criterion without affecting the risk criterion.
Blocks 8–9.
The requirements M1–M2 regarding the monotonic influence of changes in associated parameters on the costs are checked. If these requirements are not met for any parameters, the corresponding constraint adjustments are abandoned.
The admissibility of the maximal possible reduction in the productivity and the maximal possible increase in emissions, which result from cost minimization, is verified. If the total reduction in the productivity exceeds the specified value d3 and/or the total increase in emissions exceeds the allowable values d4, acceptable constraints are selected. Under the chosen constraints, the requirements for d3 and d4 must be satisfied, e.g., preference is given to those constraints for which adjustment results in the smallest reduction in productivity. If any suitable constraint cannot be found, minimizing the costs is abandoned.
Block 10.
Analysis of the results of the constraint adjustment.
Additional comments on the adjustment of constraints.
Reductions in the productivity associated with decreases in the accident risk, emissions, and costs, as well as increases in emissions resulting from cost reductions, are determined based on technological relationships and/or expert evaluation methods [61]. The information required for these assessments is provided by technologists, operators, and process developers.
When estimating the reduction in the productivity P (the increase in emissions E), the presence of a monotonic influence of the considered constraint on the productivity is analyzed over the range in which the constraint changes (Dk or Vk). If no monotonic influence is observed, the corresponding constraint is not corrected.
It is possible that adjusting the constraint may lead to a decrease in productivity, but the maximum possible decrease cannot be estimated. Then, this constraint should not be corrected.
In cost optimization, it is possible that adjusting the constraint may lead to an increase in emissions, but the maximum possible increase cannot be estimated. Then, this constraint should also not be corrected.
The strategy can be applied for a small number of selected key parameters which affect the environment. In the adjusting of constraints on parameters, the above-mentioned procedures can be implemented with different values of Dk and Vk. Then, the analysis is carried out, and the most suitable option is selected.
In some cases, the adjusted constraints for various technological situations can be approximated as functions of input variables and/or the actual state of the catalyst, e.g., in ammonia production, the lower operating temperature boundary in the reaction zone can be increased with the decrease in the fresh mixture feed and/or during the catalyst aging. Then, risks of reaction extinguishing and further forced emergency shutdown are reduced.
Extended Ecology–Technological Portfolios and Techno-Ecological Matrixes can be used to realize various tasks aimed at improving the environmental and economic efficiency of CTS. Examples of such tasks are given in Table 4.
The methodological approaches presented in this work are unified under the general concept of the Rational Methodology of Efficiency Increasing (RMEI). In Table 5, this methodology is compared with other ones aiming at improving the efficiency of control—both manual control (MC) and traditional static control (TSC). Traditional control based on the criterion of the maximum productivity is performed for the normal technological mode.
In considering the RMEI methodology, the objective function includes three criteria: the productivity of the technological process for the target product, the costs, and the risk of accidents. The comparative analysis, the results of which are presented in Table 5, is carried out according to the criteria mentioned above. The comparison also includes the impact of the CTS on the environment, the implementation of specialized measures for risk reduction, and the ability of the system to operate under critical situations.

4. Discussion

What is the exact meaning of the term “eco-efficiency”? Is it a method? Or a strategy? Or an approach? Or a set of requirements?
In the present paper, the eco-economic efficiency is considered as one of the key characteristics of control.
The Rational Methodology of Efficiency Increasing (RMEI) is presented through a set of strategies and models developed by us, in line with its stated aim.
Improving the eco-economic efficiency via control including accident prevention can be viewed as an optimization problem with a vector objective function. The central focus in solving this problem is the development of praxis-oriented rules for overcoming the uncertainty of goals.
The challenge of vector optimization arises from the fact that the optimal solutions, which correspond to different objective functions, typically do not coincide. Nevertheless, in a number of practical cases, an improvement in one criterion may be accompanied by enhancements in one or more other criteria. Therefore, it is reasonable to consider this possibility when solving the overall problem of improving CTS eco- efficiency.
Accident prevention forms the foundation for improving the eco-efficiency of chemical–technological systems. Special interest should be given to the favorable prevention of accidents, which is economically and environmentally beneficial both for hazardous process disturbances and in normal operation.
In the proposed methodology, the vector objective function for the CTS includes at least one criterion that directly influences global economic goals. In a number of cases, productivity may serve as such a criterion (see Section 3.1 for details).
In our methodology, the uncertainty regarding the characteristics of the control object in stabilization tasks is compensated for by using special approaches to accident prevention, with a focus on the development of rational problem-oriented models (Section 3.2).
The uncertainty of the operator actions is compensated for by applying strategies based on the principle of guaranteed results [1].
Extended Ecology–Technological Portfolios allow us to analyze the impact of technological processes on the environment in the absence of complete mathematical models.
It is possible to make an approximate assessment of various types of losses, including production costs under normal operating conditions, as well as losses, both short-term and long-term, caused by accidents.
Conditions for the quasi-optimal improvement of environmental criteria through the adjustment of technological constraints have been formulated.
Rational organization of the technological process and its control leads to the combined improvement of both economic and ecological criteria.
The integration of environmental factors into CTS control can be considered as one of the additional tools of the marketing mix, which enhances both the process efficiency and its competitive advantage.
The presented strategies and models may be applied in the design of control systems for industrial chemical processes, e.g., for autothermal reactors, synthesis columns, reforming systems, and absorbers.
This work focuses on improving the environmental and economic efficiency via CTS control. Also, some of the obtained results can be applied to other tasks aimed at enhancing the efficiency of complex technological facilities (see different cases in Table 4).
The developed RMEI can be complemented by additional approaches and models.

5. Conclusions

This paper presents a rational methodology for improving the ecological and economic efficiency of chemico-technological systems.
The problem of achieving high eco-efficiency is solved as a vector optimization control problem with economic and ecological objectives, including the risk. When solving the problem, recognition, prevention, and elimination of critical situations are also ensured.
The risk minimization criterion, which is a part of the vector objective function, has special priority because accidents lead to significant economic and environmental losses. The difficulty of precise numerical risk assessment has been noted.
An approach to overcoming the uncertainty of control objectives is presented. It is based on the system of priorities among the local criteria and specified complementary procedures for risk decrease. The system of criteria priorities is changed depending on different operation modes.
The subtasks of overall vector optimization for the chemico-technological process have been presented. The coordination and correctness of the subtasks have been demonstrated.
A structural schematic of the system for enhancing the eco-economic efficiency is presented. The interactions between the subsystems are shown.
This paper demonstrates the advisability of combining standard multi-criteria optimization procedures with procedures focused on the concrete properties of the specific CTS.
Some procedures that improve certain criteria without worsening, and sometimes with improving, other criteria, have been shown.
Approaches to improving the efficiency of stabilization systems for accident prevention have been presented. These approaches can be used in the control of various potentially hazardous technological processes.
Extended Ecological–Technological Portfolios have been developed as approximate visual models that characterize the impact of a control object on the environment. Portfolios illustrate the influence of technological disturbances on environmental criteria. They allow us to investigate the CTS for increasing eco-efficiency and preventing accidents.
The concepts of the Ecological–technological Vector and the Ecological–Technological Matrix have been introduced. These Matrices are developed based on Portfolios and characterize technological disturbances. The Vectors and Matrices make it possible to purposefully analyze the control object, identify potential hazards, and create prerequisites for improving eco-efficiency.
The strategy for adjusting the technological constraints to enhance the eco-efficiency of the CTS has been proposed.
The developed Ecological–Technological Portfolios and Matrices can be applied in data preparation for various artificial intelligence tasks aimed at improving the environmental and economic efficiency of the CTS.
The areas for application of the obtained results, as well as the corresponding limitations, are indicated.
In this paper, numerous examples have been presented and analyzed.

6. Future Directions

Presently, we are continuing our work on accident prevention and improving the efficiency of chemical process systems. In particular, our areas of interest include the following:
  • Development of accident-free control systems for autothermal reactors, using the Rational Methodology of Efficiency Increasing (RMEI) and modeling the corresponding systems;
  • Development of maps of potentially hazardous processes based on Extended Ecological–technological Portfolios and using the RMEI;
  • Development of approaches for creating real-time dynamic gray-box models of chemical reactors. The potential applications are systems for training operators, process simulators, and digital twins.

Author Contributions

Conceptualization, G.Y. and A.F.; methodology, G.Y. and A.F.; formal analysis, G.Y. and A.F.; writing—original draft preparation, G.Y. and A.F. All authors have read and agreed to the published version of the manuscript.

Funding

This research received no external funding.

Data Availability Statement

The data are contained within the article.

Conflicts of Interest

The authors declare no conflicts of interest.

Nomenclature

Latin letters
ak,1, ak,2, ak,3, ak,4components of the techno-ecological vector Tk
Arisk of accidents
bk,1, bk,2, bk,3, bk,4components of the techno-ecological vector Tk
cgain parameter (°C/%)
d, d1d3limitations on decrease in productivity (t/h)
d4limitation on increase in emissions (t/h)
Dkamount of reduction in the upper limit Hk
Eemissions (t/h)
Gset of admissible solutions in the problem with objective function (1)
Hkupper limits on controlled parameters
Krspecific cost associated with the r-th control used to eliminate the critical situation
kggain parameter (°C/%)
Lresulting costs (USD/h)
Nklower limits on controlled parameters
Pproductivity (t/h)
Rvector objective function
Recon, ieconomical components of vector objective function
Recol, jecological components of vector objective function
ttime (s)
T, Tetime constants (s)
Tktechno-ecological vector
uposition of the gas supply valve to the reaction zone (%)
uc,rr-control action in the respective control loop of the subsystem 2
u ξ . control action that causes the change in the parameter zk,
Ucontrol vector of CTS
Ue,Uccontrol vectors of the subsystems 1 and 2
Vkamount of increase in the lower limit Nk
Xvector of input variables of CTS
Xe, Xcinput vectors of the subsystems 1 and 2
Xfvector of input variables affecting the temperature y f
yccontrolled variable in the subsystem 2
yeoutput variable in the subsystem 1
yf, yumean and maximum temperatures in the reaction zone, (°C)
zcdisturbance in the subsystem 2
zesum of external and internal disturbances in the subsystem 1
zkcontrolled process parameter
zudisturbance for the maximum temperature in the reaction zone (°C)
Zvector of controlled process parameters included in the system of technological constrains
Greek letters
ξ index of the control action that causes a change in the parameter zk
φ 1   φ 2 , φ 3 functions of vector X f
Ψsequence of activation of the auxiliary control loops
Ψ 1 , l , Ψ 2 , s , Ψ 3 , l functions of vector X e
Ψ 4 , s   Ψ 5 functions of vector X e
Ω set of admissible solutions in the problem with objective function (2)
Subscripts
iindex of scalar economic criteria, i = 1,…, n
jindex of scalar ecological criteria, j = 1,…, m
kindex of the controlled parameter and technological fault, k = 1,…, p
lindex of control action in the subsystem 1, l = 1,…, λ
rindex of control action in the subsystem 2 and the respective control loop, r = 0 ,   , q
sindex of input variables in the subsystem 1, s = 1,…, µ
Abbreviations
ACGammonia production from coke oven gas
EETPextended ecological–technological portfolio
ANGammonia production from natural gas
ETPeconomic–technological portfolio
CTSchemico-techological system
SATCstrategy for adjusting the technological constraints
MCmanual control
RMEIrational methodology of efficiency increasing
TEMtechno-ecological matrix
TEVtechno-ecological vector
TSCtraditional static control
VOFvector objective function

References

  1. Fedorov, A.; Yablonsky, G. Critical Situations and Prevention of accidents in Chemico-Technological Systems (Methodological Aspects). Processes 2024, 12, 161. [Google Scholar] [CrossRef] [Scilit]
  2. Hao, X.; Wen, S.; Xue, Y.; Wu, H.; Hao, Y. How to improve environment, resources and economic efficiency in the digital era? Resour. Policy 2023, 80, 103198. [Google Scholar] [CrossRef] [Scilit]
  3. Chen, Y.; Song, G.; Yang, F.; Zhang, S.; Zhang, Y.; Liu, Z. Risk Assessment and Hierarchical Risk Management of Enterprises in Chemical Industrial Parks Based on Catastrophe Theory. Int. J. Environ. Res. Public Health 2012, 9, 4386–4402. [Google Scholar] [CrossRef] [Scilit]
  4. Ökoeffizienz. Available online: https://de.wikipedia.org/wiki/%C3%96koeffizienz (accessed on 20 May 2024).
  5. Eco-Efficiency. Available online: https://www.ecomatters.nl/services/lca-epd/life-cycle-assessment/eco-efficiency-analysis/ (accessed on 7 June 2025).
  6. Kopnina, H.; Blewitt, J. Sustainable Business; Routledge: London, UK, 2018; Available online: https://www.taylorfrancis.com/books/mono/10.4324/9781315110172/sustainable-business-john-blewitt-helen-kopnina (accessed on 23 January 2026).
  7. Fussler, C. Die Öko-Innovation: Wie Unternehmen Profitabel und Umweltfreundlich Sein Können; S. Hirzel Verlag GmbH: Stuttgart, Germany, 1999; Available online: https://www.amazon.de/Die-%C3%96ko-Innovation-Unternehmen-profitabel-umweltfreundlich/dp/3777608742 (accessed on 23 January 2026).
  8. Ökoeffizienz. Available online: https://wupperinst.org/a/wi/a/s/ad/211 (accessed on 21 May 2024).
  9. Fedorov, A.; Stefan, T.; Noisser, R.; Weinmann, A. Vermeidung und Beseitigung von Notfallsituationen mit regelungstechnischen Lösungen. Int. J. Autom. Austria 1999, 7, 2–17. [Google Scholar]
  10. de Oliveira Neto, G.C.; Lucato, W.C. Production planning and control as a tool for eco-efficiency improvement and environmental impact reduction. Prod. Plan. Control 2015, 27, 148–156. [Google Scholar] [CrossRef] [Scilit]
  11. Beder, S. Environmental economics and ecological economics: The contribution of interdisciplinarity to understanding, influence and effectiveness. Environ. Conserv. 2011, 38, 140–150. [Google Scholar] [CrossRef] [Scilit]
  12. Methodensammlung zur Nachhaltigkeitsbewertung. Grundlagen, Indikatoren. Hilfsmittel. Karlsruher Institut für Technologie—KIT. Available online: https://www.iip.kit.edu/downloads/Methodensammlung%20zur%20Nachhaltigkeitsbewertung.pdf (accessed on 6 November 2025).
  13. Nachhaltige Chemie. Positionen und Kriterien des Umweltamtes. Available online: https://www.umweltbundesamt.de/themen/nachhaltigkeit-strategien-internationales (accessed on 23 January 2026).
  14. Saling, P.; Kicherer, A.; Dittrich-Krämer, B.; Wittlinger, R.; Zombik, W.; Schmidt, I.; Schrott, W.; Schmidt, S. Eco-efficiency analysis by BASF: The method. Int. J. Life Cycle Assess. 2002, 7, 203–218. Available online: https://www.researchgate.net/publication/226248943_Eco-efficiency_analysis_by_BASF_The_method (accessed on 23 January 2026). [CrossRef] [Scilit]
  15. Ökoeffizienz-Analyse. Available online: https://www.google.com/url?sa=t&source=web&rct=j&opi=89978449&url=https://www.basf.com/global/de/who-we-are/sustainability/our-contributions-to-enabling-the-green-transformation/eco-efficiency-analysis&ved=2ahUKEwiv9M20yOeQAxWm1QIHHbGIHZIQFnoECBUQAw&usg=AOvVaw2YVdjAV2jI1MlPslsPCPU3 (accessed on 10 November 2025).
  16. Fedorov, A.; Weber, M.; Frei, H.; Kenig, E.Y. Dynamisches Grey-Box-Modell des Prozesses der chemischen Absorption für Echtzeitanwendungen. Chem. Ing. Tech. 2025, 97, 195–203. [Google Scholar] [CrossRef] [Scilit]
  17. Fedorov, A.; Frei, H.; Bothe, M.; Lutters, N.; Kenig, E.Y. Entwicklung von Echtzeitmodellen für Kreislaufprozesse der chemischen Absorption. Chem. Ing. Tech. 2020, 92, 1962–1967. [Google Scholar] [CrossRef] [Scilit]
  18. Bothe, M.; Fedorov, A.; Frei, H.; Lutters, N.; Kenig, E.Y. Untersuchung des dynamischen Prozessverhaltens bei Betriebsstörungen im Bereich der chemischen Absorption. Chem. Ing. Tech. 2020, 92, 299–304. [Google Scholar] [CrossRef] [Scilit]
  19. Arendt, J.S. Management of quantitative risk assessment in the chemical process industry. Process Saf. Prog. 1990, 9, 262–268. [Google Scholar] [CrossRef] [Scilit]
  20. Achour, M.H.; Haroun, A.E.; Schult, C.J.; Gasem, K.A.M. A new method to assess the environmental risk of a chemical process. Chem. Eng. Process. 2005, 44, 901–909. [Google Scholar] [CrossRef] [Scilit]
  21. Schmitz, P.; Reniers, G.; Swuste, P. Determining a realistic ranking of the most dangerous process equipment of the ammonia production process: A practical approach. J. Loss Prev. Process Ind. 2021, 70, 104395. [Google Scholar] [CrossRef] [Scilit]
  22. Risk Identification. Available online: https://www.mitre.org/publications/systems-engineering-guide/acquisition-systems-engineering/risk-management/risk-identification (accessed on 6 December 2025).
  23. Heinze, E.; Biwer, A.; Eissen, M.; Abdul Kholig, M. Bewertung biotechnologischer Prozesse in frühen Phasen der Entwicklung hinsichtlich Risiken bezüglich Ökologie, Sicherheit und Gesundheit. Chem. Ing. Tech. 2006, 78, 301–305. [Google Scholar] [CrossRef] [Scilit]
  24. Utkin, V.; Fedorov, A. Prevention of emergency situations with sliding mode control. In Proceedings of the 11th IEEE International Workshop on Variable Structure Systems (VSS), Mexico City, Mexico, 26–28 June 2010; pp. 136–141. Available online: https://www.researchgate.net/publication/251943055_Prevention_of_emergency_situations_with_sliding_mode_control (accessed on 23 January 2026).
  25. Yablonsky, G. Kinetic models of catalytic reactions, V. 32. In Comprehensive Chemical Kinetics; Elsevier: Amsterdam, The Netherlands, 1991. [Google Scholar]
  26. Marin, G.B.; Yablonsky, G.S.; Constales, D. Kinetics of Chemical Reactions, Decoding Complexity; Wiley-VCH Verlag GmbH & Co. KGaA: Weinheim, Germany, 2019. [Google Scholar]
  27. Yablonsky, G.; Ray, A. Equilibrium and Optimum: How to Kill Two Birds with One Stone? Int. J. Chem. React. Eng. 2008, 6, 36–48. [Google Scholar] [CrossRef] [Scilit]
  28. Hopfenbeck, W. Umweltorientiertes Management und Marketing; Moderne Industri: Landsberg/Lech, Germany, 1990. [Google Scholar]
  29. Steger, U. Umweltmanagement; Gablerverlag: Wiesbaden, Germany, 2013. [Google Scholar]
  30. Zimmermann, H.J.; Gutsche, L. Multi-Criteria Analyse; Springer: Berlin/Heidelberg, Germany, 1991. [Google Scholar]
  31. Moiseev, N.N. Mathematical Problems of Systems Analysis; Editorial URSS: Moscow, Russia, 2013; Available online: https://urss.ru/cgi-bin/db.pl?lang=Ru&blang=ru&page=Book&id=170868&srsltid=AfmBOopTaxw4fh32N7WzCZN27dBjRANnne8CKNKD0H5GBt6X6bdNoSTX (accessed on 23 January 2026).
  32. Seidel, E.; Strebel, H. Umwelt und Oekonomie; Gabler: Wiesbaden, Germany, 1991. [Google Scholar]
  33. Fedorov, A.; Statjuha, G. Algorithm of decision-making by control of complex chemico-technological object. Chem. Technol. 1987, 4, 70–72. (In Russian) [Google Scholar]
  34. Luptacik, M.; Bohm, B. An environmental input-output model with multiple criteria. Ann. Oper. Res. 1994, 54, 119–127. Available online: https://www.google.com/url?sa=t&source=web&rct=j&opi=89978449&url=https://link.springer.com/article/10.1007/BF02031730&ved=2ahUKEwjawPGApLOSAxUslP0HHUHYHQ4QFnoECCsQAQ&usg=AOvVaw0t25q0kuE5_aXUeThBEj1W (accessed on 23 January 2026). [CrossRef] [Scilit]
  35. Fedorov, A. Control system for ammonia units. Control Syst. Comput. 1991, 3, 120–124. (In Russian) [Google Scholar]
  36. Belton, V.; Stewart, T. Multiple Criteria Decision Analysis—An Integrated Approach; Kluwer Academic Press: Boston, MA, USA, 2002. [Google Scholar]
  37. Jahn, J. Vector Optimization: Theory, Applications, and Extensions; Springer: Berlin/Heidelberg, Germany, 2011; Available online: https://www.google.com/url?sa=t&source=web&rct=j&opi=89978449&url=https://link.springer.com/book/10.1007/978-3-642-17005-8&ved=2ahUKEwib-eKZlaSSAxXYVfEDHUpSCI0QFnoECBAQAQ&usg=AOvVaw1UHGf1iPpa6oRA_jfmVFFE (accessed on 23 January 2026).
  38. Figueira, J.; Greco, S.; Ehrogott, M. Multiple Criteria Decision Analysis—State of the Art Surveys; Springer: New York, NY, USA, 2016; Available online: https://www.researchgate.net/publication/327333063_Figueira_J_Greco_S_Ehrgott_M_Multicriteria_Decision_Analysis_State_of_the_art_Surveys_Springer-Verlag_New_York_NY_2016 (accessed on 23 January 2026). [CrossRef] [Scilit]
  39. Merzlikina, G.S. Environmental economic efficiency of industrial enterprises: Evaluation and management. Vestnik of Astrakhan State Technical University. Ser. Econ. 2019, 3, 7–20. (In Russian) [Google Scholar] [CrossRef] [Scilit]
  40. Fedorov, A.V.; Korchaka, N.I.; Kisil, I.M.; Kotovenko, E.A.; Shablij, A.G.; Andrianov, V.V.; Krot, V.G. Method of Ammonia Production Control. UA Patent 9449, 30 September 1996. [Google Scholar]
  41. Rangaiah, G.P.; Feng, Z.; Hoadley, A.F. Multi-Objective Optimization Applications in Chemical Process Engineering: Tutorial and Review. Processes 2020, 8, 508. [Google Scholar] [CrossRef] [Scilit]
  42. Usheva, N.V.; Moizes, O.E.; Mityanina, O.E.; Kuzmenko, E.A. Mathematical Modeling of Chemico—Engineering Processes: A Textbook; Tomsk Polytechnic University Press: Tomsk, Russia, 2014; Available online: https://portal.tpu.ru/SHARED/o/OEM/Ucheba/Tab/Uch_posobie_Mod_XTP.pdf (accessed on 15 December 2025).
  43. Kafarov, V.V. Cybernetics Methods in Chemistry and Chemical Engineering; Khimiya: Moscow, Russia, 1985; Available online: https://www.centrmag.ru/catalog/product/etody-kibernetiki-v-himii-i-himicheskoy-tehnologii-4-e-izdanie/ (accessed on 23 January 2026).
  44. Kafarov, V.V.; Glebov, M.B. Mathematical Modeling of Basic Processes of Chemical Production; URSS: Moscow, Russia, 2023; Available online: https://urss.ru/cgi-bin/db.pl?lang=Ru&blang=ru&page=Book&id=240899&srsltid=AfmBOoprc0SdmD2_ZrC7O__w9JuUV6dKt_h8PkhqkeC1sFDcTejUkVnW (accessed on 23 January 2026).
  45. Ponce-Ortega, J.M.; Ochoa-Barragán, R.; Ramírez-Márquez, C. Optimization of Chemical Processes: A Sustainable Perspective; Springer: Cham, Switzerland, 2024; Available online: https://www.researchgate.net/publication/380310246_Optimization_of_Chemical_Processes_A_Sustainable_Perspective (accessed on 23 January 2026).
  46. Robin Smith, R. Chemical Process Design and Integration; John Wiley & Sons Ltd.: Chichester, UK, 2016; Available online: https://www.google.com/url?sa=t&source=web&rct=j&opi=89978449&url=https://www.wiley.com/en-us/Chemical%2BProcess%2BDesign%2Band%2BIntegration%252C%2B2nd%2BEdition-p-9781119990147&ved=2ahUKEwiH18z7r6SSAxWlA9sEHRnMFPcQFnoECBAQAQ&usg=AOvVaw3BhNMHDvIr737DiccPA34j (accessed on 23 January 2026).
  47. Shardt, Y.A.W. Statistics for Chemical and Process Engineers: A Modern Approach, 1st ed.; Springer Nature: Cham, Switzerland, 2022; Available online: https://books.google.de/books/about/Statistics_for_Chemical_and_Process_Engi.html?id=rN9XEAAAQBAJ&redir_esc=y (accessed on 23 January 2026).
  48. Sridha, D.V.; Seagrave, R.C.; Bartlett, E.B. Process modeling using stacked neural networks. AIChE J. 1996, 42, 2529–2539. [Google Scholar] [CrossRef] [Scilit]
  49. Upreti, S.R. Process Modeling and Simulation for Chemical Engineers: Theory and Practice; John Wiley & Sons Ltd.: Hoboken, NJ, USA; Chichester, UK, 2017; Available online: https://content.e-bookshelf.de/media/reading/L-9747059-78f83fb599.pdf (accessed on 23 January 2026).
  50. Rotatsch, V.Y. Theory of Automatic Control of Thermal Power Processes; Energoatomizdat: Moscow, Russia, 1985; Available online: http://tes.kpi.ua/wp-content/uploads/2020/04/1985-%D0%A0%D0%BE%D1%82%D0%B0%D1%87-%D0%92.-%D0%AF.-%D0%A2%D0%B5%D0%BE%D1%80%D0%B8%D1%8F-%D0%B0%D0%B2%D1%82%D0%BE%D0%BC%D0%B0%D1%82%D0%B8%D1%87%D0%B5%D1%81%D0%BA%D0%BE%D0%B3%D0%BE-%D1%83%D0%BF%D1%80%D0%B0%D0%B2%D0%BB%D0%B5%D0%BD%D0%B8%D1%8F-%D1%82%D0%B5%D0%BF%D0%BB%D0%BE%D1%8D%D0%BD%D0%B5%D1%80%D0%B3%D0%B5%D1%82%D0%B8%D1%87%D0%B5%D1%81%D0%BA%D0%B8%D0%BC%D0%B8-%D0%BF%D1%80%D0%BE%D1%86%D0%B5%D1%81%D1%81%D0%B0%D0%BC%D0%B8.pdf (accessed on 23 January 2026).
  51. Schulz, G. Regelungstechnik 1, 3. Auflage; Oldenbourg Wissenschaftsverlag: München, Germany, 2007; Available online: https://api.pageplace.de/preview/DT0400.9783486594027_A21723424/preview-9783486594027_A21723424.pdf (accessed on 23 January 2026).
  52. Medvedev, R.B.; Muravjev, A.I.; Fedorov, A.V.; Shljachanov, A.N. Algorithms for checking the reliability of parameter values in the information subsystem of the system for computer process control. Chem. Technol. 1977, 4, 51–52. (In Russian) [Google Scholar]
  53. Castillo, I.; Steinberger, M.; Fridman, L.; Moreno, J.A.; Horn, M. A Lyapunov based Saturated Super-Twisting algorithm. In Emerging Trends in Sliding Mode Control, Studies in Systems, Decision and Control; Mehta, A., Bandyopadhyay, B., Eds.; Springer Nature Singapore Pte Ltd.: Singapore, 2021; Available online: https://www.tugraz.at/fileadmin/user_upload/Institute/IRT/Clover/A_Lyapunov_based_Saturated_Super-Twisting_Algorithm.pdf (accessed on 23 January 2026).
  54. Der Windup-Effekt bei Reglern mit Begrenzten Stellgrößen. Available online: http://www.kramann.info/62_Regelungssysteme/11_Stabilitaet/03_Windup/ (accessed on 6 December 2025).
  55. Wang, D.D. Unravelling the Effects of the Environmental Technology Portfolio on Corporate Sustainable Development. Corp. Soc. Responsib. Environ. Manag. 2018, 25, 457–472. [Google Scholar] [CrossRef] [Scilit]
  56. Social-Ecological-Technological Systems (SETS). Available online: https://www.researchgate.net/publication/373647349_Resilience_of_Urban_Social-Ecological-Technological_Systems_SETS_A_Review (accessed on 23 January 2026).
  57. Ciullo, A.; Viglione, A.; Castellarin, A.; Crisci, M.; Di Baldassarre, G. Socio-hydrological modelling of flood-risk dynamics: Comparing the resilience of green and technological systems. Hydrol. Sci. J. 2017, 62, 880–891. [Google Scholar] [CrossRef] [Scilit]
  58. Portfolios. Available online: https://www.google.com/url?sa=t&source=web&rct=j&opi=89978449&url=https://www.siemens-energy.com/global/en/home/products-services/product-offerings/blue-high-voltage-products.html&ved=2ahUKEwi-o9a3_bCSAxWS_7sIHaUCEMUQFnoECBwQAQ&usg=AOvVaw35UdgCo3l-sO8jQINTs5VF (accessed on 23 January 2026).
  59. Grubler, A.; Wilson, C. Energy Technology Innovation; Cambridge University Press: Cambridge, UK, 2013; Available online: https://www.cambridge.org/core/books/abs/energy-technology-innovation/energy-technology-innovation/80016D8AFCBB459D397301F0ECD68938 (accessed on 23 January 2026). [CrossRef] [Scilit]
  60. Danesh, D.; Ryan, M.J.; Abbasi, A. Multi-criteria decision-making methods for project portfolio management: A literature review. Int. J. Manag. Decis. Mak. 2017, 17, 75–94. [Google Scholar] [CrossRef] [Scilit]
  61. Methods for Expert Evaluation. Available online: https://habr.com/ru/articles/189626/ (accessed on 15 April 2024).
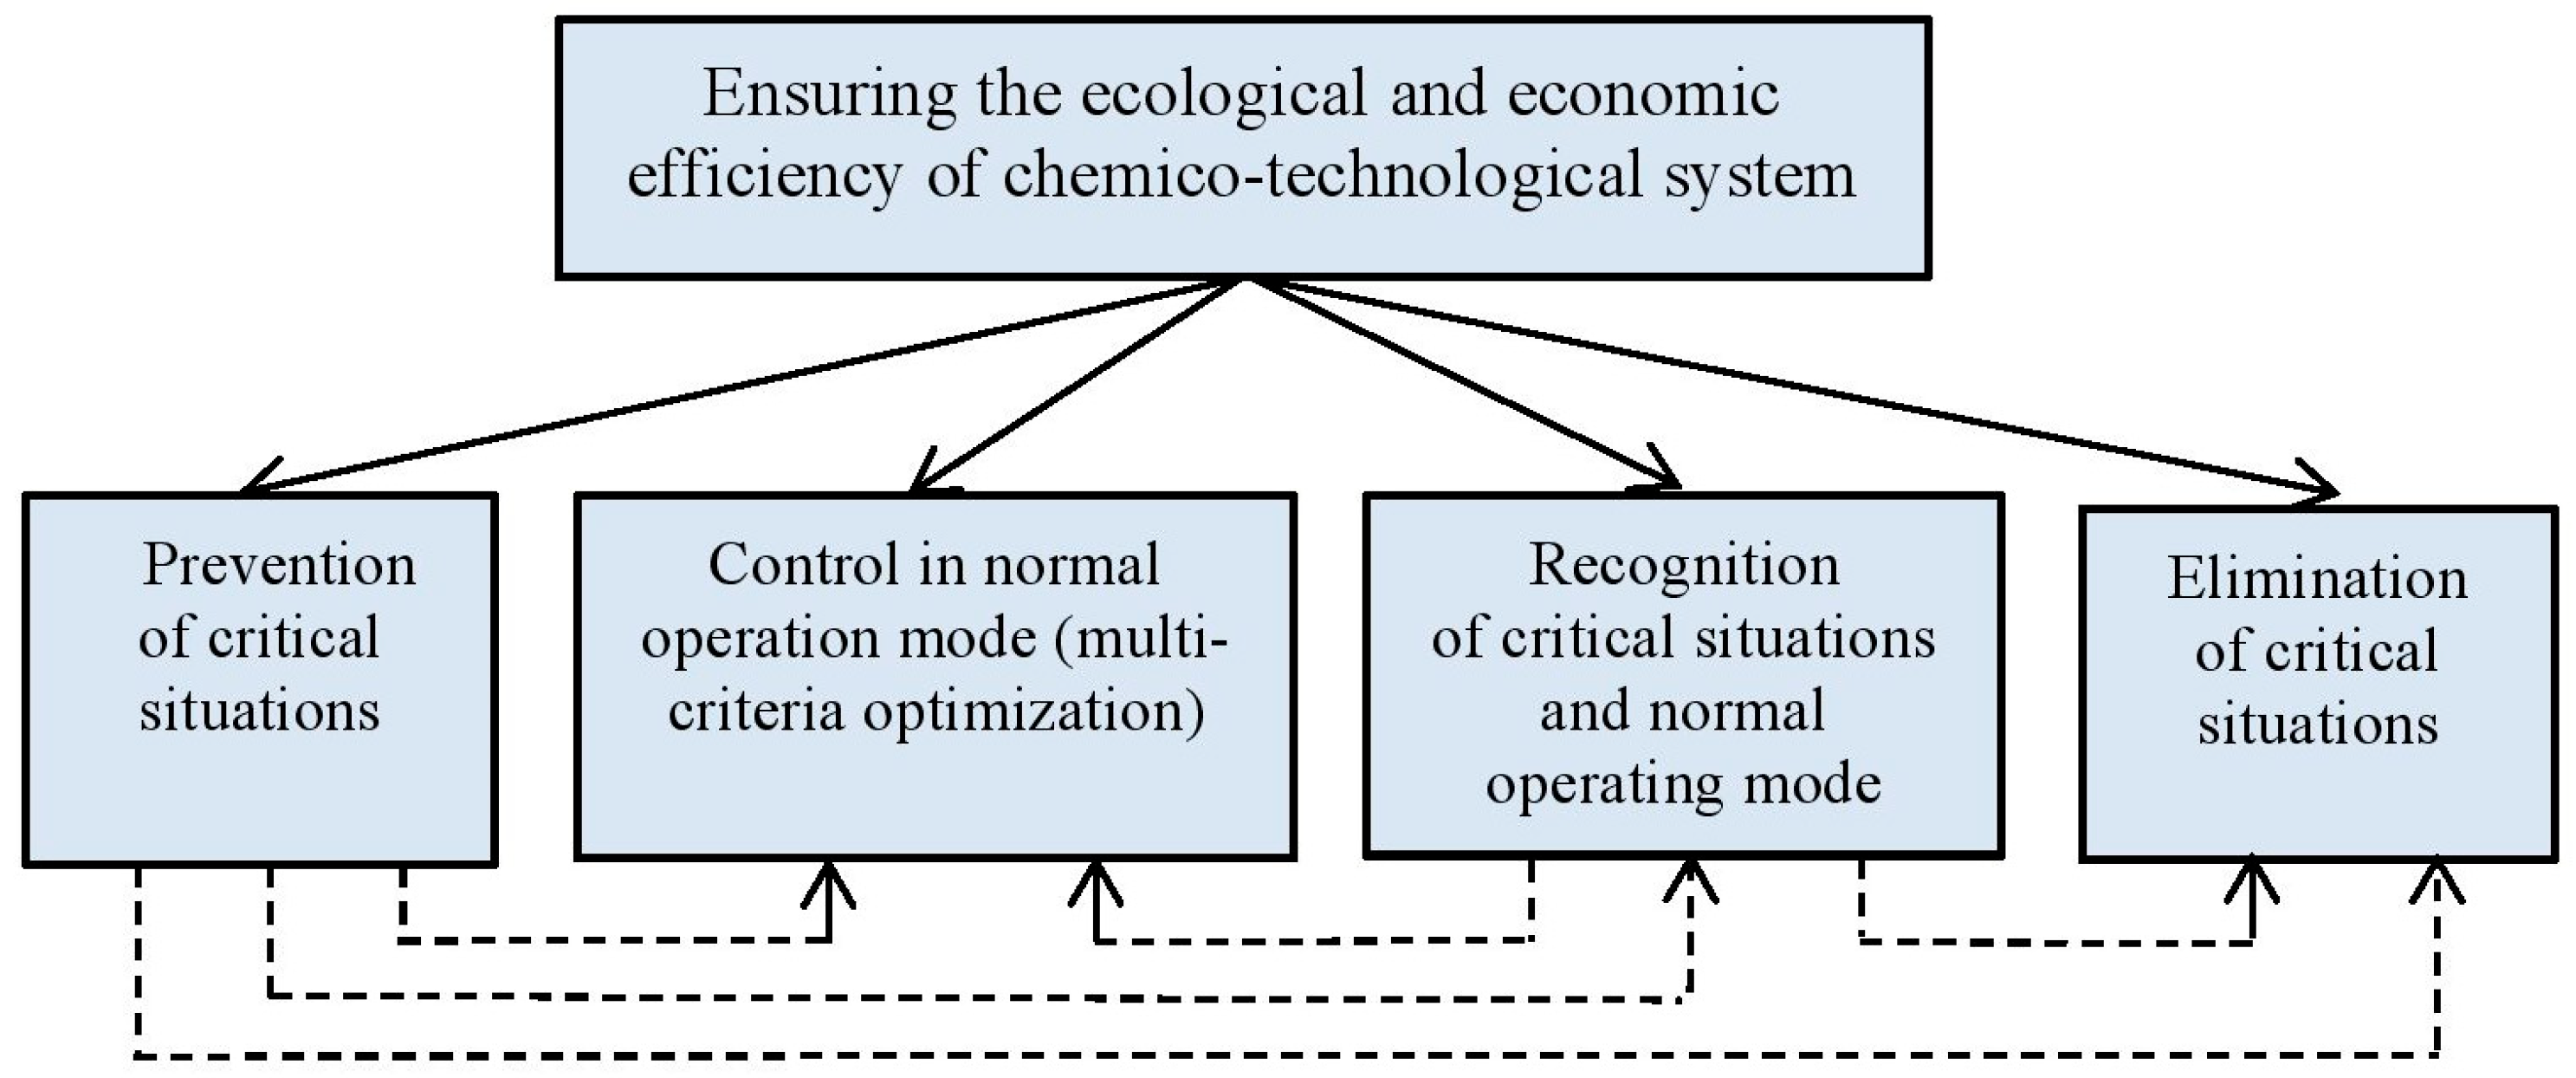
Figure 1. Improving the ecological and economic efficiency of the CTS.
Processes 14 00524 g001
Figure 2. Decomposition and adjustment of the model.
Processes 14 00524 g002
Figure 3. Control object (subsystem 1). Xc—the input vector, yc—the controlled variable, u c , 0 —the control action in the main control loop, u c , 1 , u c , r , …, u c , q —the control actions in the auxiliary control loops, zc—the disturbance.
Processes 14 00524 g003
Figure 4. Consecutive emergency control.
Processes 14 00524 g004
Figure 5. Extended Ecology–Technological Portfolio (Type 1).
Processes 14 00524 g005
Figure 6. Extended Ecology–Technological Portfolio (Type 2).
Processes 14 00524 g006
Figure 7. ‘Symmetrical’ Portfolio (Type 3).
Processes 14 00524 g007
Figure 8. Strategy for adjusting the constraints of technological parameters.
Processes 14 00524 g008
Table 1. Definitions of eco-efficiency.
NoDefinitionSource (References)
1Eco-efficiency is the ratio of the economic value of a product to the environmental impact caused by its production process, measured in an appropriate unit[4]
2Eco-efficiency is an emerging method for transforming unsustainable development into sustainable development. Specifically, the eco-efficiency calculation determines the ratio between the value of products and their environmental impacts and gives clear financial results. These insights help create more goods and services with the use of fewer resources. As a result, this creates less waste and pollution and can improve the bottom line[5]
3Eco-efficiency is based on the idea of “doing more with less,” that is, reducing the consumption of resources (e.g., energy) and the impact on nature (e.g., air pollution) while maintaining or increasing the value of the manufactured product[6]
4Eco-efficiency—commonly understood as “producing more with less energy and resource consumption”—is described by the former Dow Chemical manager Claude R. Fussler as the idea “that environmental performance and business success go hand in hand”[7]
Table 2. Analyses of developed Extended Ecology–Technological Portfolios for ammonia production processes.
No.Technological FaultsMain Ecological ConsequencesCorresponding Ecological CriteriaCorresponding Type of EETPCorresponding Point on EETP
1Loss of the thermal stability of the ammonia synthesis reactor (ACG), emergency decrease in the temperature in the reaction zoneEmergency shutdown with emission of coke oven gas, CO2, and NH3 is possibleEnvironmental pollution11
2Emergency pressure increase in system of circulation (ACG)Emissions of circulating gasEnvironmental pollution11
3Emergency increase in the temperature of the reformed gas in the primary methane reformer (ANG)Explosion and fire caused by burning-out of reactor tubesRisk12
4Increase in steam surplus in steam/gas ratio control (ANG)Small increase in CO2 emissions in smoke-gasesEnvironmental pollution13
5Dangerous frequency of temperature fluctuations in the reaction zone (ANG and ACG)Gas leakages, possibility of explosion and fire
Factors: temperature stresses in structural elements of the reactor, loss of reactor impermeability
Risk of pollution, explosion, and fire12
6Emergency decrease in natural gas feed (ANG)Reduction of purge-gas and smoke-gas emissions, along with a potential decrease in fuel gas consumptionEnvironmental pollution, resource saving36
7Small violations in the nitrogen–hydrogen mixture concentration (ANG and ACG)No noticeable environmental changesEcological criteria practically do not vary27
8Decrease in temperature in the methane reformer (ANG)Small decrease in the risk of tube burnout in the reformerRisk of pollution, explosion, and fire36
9Increase in the concentration of inert gases in the circulation mixture (ANG)Increase in energy and resource consumptionResource saving14
Table 3. Developed Techno-Ecological Matrix for ammonia production (ACG).
Nr.ParameterIndex of Control ActionLow BoundarySmall Violation of the Lower BoundaryUpper BoundarySmall Violation of the Upper Boundary
RiskEnvironmental PollutionResource Consumption (Costs)RiskEnvironmental PollutionResource Consumption (Costs)
1H2/N2 ratio
110011001
2Ammonia concentration at the reactor inlet200001312
3Liquid ammonia level in the evaporator
313121312
4Temperature in the reaction zone of the ammonia synthesis reactor413111312
Table 4. Application of Extended Ecology–Technological Portfolios and Techno-Ecological Matrixes.
No.TaskField of Application
1Data preparation for artificial intelligence solutions:
development of knowledge bases and expert systems for potentially hazardous CTS, design of systems based on fuzzy logic, artificial neural networks, and evolutionary modeling
Control,
safety,
training and professional development
2Formulation of environmental requirements for design and operation of chemical plantsDevelopment and improvement of technological processes and units
3Identification of potential hazards in chemical process controlSafety
4Comprehensive assessment of losses caused by process violationsControlling
5Targeted investigation of the CTS for solving multi-criteria optimization problemsComputer control
6Creation of control object maps, i.e., a visual representation of the object’s behavior in critical situationsSafety
7Monitoring of operator performance/efficiencyComputer control, Controlling
8Statistical analysis of emergency situationsSafety
9Comparison of hazards caused by violations of technological constraintsSafety
10Comparative safety evaluation of different technological processes for the same productDevelopment and improvement of technological processes and units
11Development of additional constraints beyond technological regulations Computer control, operation of the chemical plant
12Training specialists. Fostering ecological cultureTraining and professional development
Table 5. Comparison of methodologies for improving the environmental and economic efficiency of the CTS.
Methodologies of ControlCompared Characteristics
ProductivityCostsRiskConsideration of CTS Impact on the EnvironmentPrevention of AccidentsOperation in Critical Situations
Manual Control (MC)Lower than in the TSC caseDifficult to assessHigher than in the RMEI caseLimited accountingQuite limitedLimited
Traditional static control (TSC)Higher than in the MC caseDifficult to assessSlightly lower than in the MC caseLimited accountingLimitedLimited
Rational Methodology of Efficiency Increasing (RMEI)Slightly lower or equal to the productivity in the TSC caseLower than or equal to TSC caseSignificantly less than in the TSC caseSignificant considerationGoal-oriented procedures for accident preventionRecognition and elimination of critical situations
Disclaimer/Publisher’s Note: The statements, opinions and data contained in all publications are solely those of the individual author(s) and contributor(s) and not of MDPI and/or the editor(s). MDPI and/or the editor(s) disclaim responsibility for any injury to people or property resulting from any ideas, methods, instructions or products referred to in the content.