


Abstract
This work proposes an Adaptive Neural Control for the asymptotic stabilization of a chain of integrators at the origin. The proposed approach addresses the stabilization of the integrator chain by means of a control law whose applied signal is structurally bounded to by the hyperbolic tangent architecture, i.e., , where z represents a weighted linear combination of the system states and a bias term. Furthermore, an adaptation law for the weights is proposed, based on the classical backpropagation algorithm for neural networks. The stability analysis is conducted using singular perturbation theory, demonstrating that, under a sufficiently high learning rate, the closed-loop system exhibits a Standard Singular Perturbation Form. This formulation allows for the analysis of the system across two distinct time scales: the adaptation dynamics (fast subsystem) and the state dynamics (slow subsystem). Based on this formulation, explicit conditions on the learning rate and the initial conditions are derived to guarantee local asymptotic stability using Tikhonov’s theorem. These conditions characterize the region of attraction and ensure that the adaptive neural controller stabilizes the system. Numerical simulations were carried out to evaluate the controller’s performance under three different scenarios: ideal conditions, initialization outside the region of attraction, and a low learning rate. These scenarios illustrate the closed-loop system behavior and validate the theoretical conditions required for asymptotic stability. Furthermore, comparative numerical simulations were conducted on an Inverted Pendulum on a Cart system to benchmark the proposed Adaptive Neural Control against Linear Quadratic Regulator, Sliding Mode Control, and Nested Saturation Function controllers. Based on the Integral of Time-weighted Squared Error performance index, the Adaptive Neural Control demonstrated a significant reduction in control effort, achieving performance improvements of up to 95.02% compared to the aforementioned strategies.
1. Introduction
The stabilization of a chain of integrators to the origin constitutes one of the most fundamental and extensively studied problems in automatic control theory [1,2]. Its relevance stems not only from its theoretical importance as a canonical form, but also from its wide practical applicability: through feedback linearization techniques, complex nonlinear systems such as robotic manipulators [3], robots with flexible joints [4], and general mechanical systems modeled by Newton’s laws [5] can be transformed into an equivalent chain of integrators. This canonical representation serves as a starting point for a broad class of control design methodologies, making the stabilization of integrator chains a central problem in nonlinear control.
Beyond these traditional applications, the rapid advancement of modern autonomous technologies has revitalized the importance of this problem. Contemporary engineering systems, such as unmanned aerial vehicles, autonomous surface vessels, and collaborative robotic platforms, often exhibit underactuated or complex nonlinear dynamics that can be structurally mapped to multiple integrator chains. In these modern paradigms, operating conditions are highly dynamic and uncertain. Consequently, achieving high-precision stabilization is no longer just a theoretical canonical exercise, but a critical safety and performance requirement. As these technologies scale in complexity and autonomy, the need for reliable and efficient stabilization techniques remains a highly active and timely area of research.
The core challenge in stabilizing such systems lies in the strict physical limitations inherent to all real applications. Integrator chains are prone to error accumulation and drift over time. Furthermore, physical actuators, like electric motors, thrusters, or mechanical valves, possess absolute operational constraints. If a theoretical control law demands an unfeasible amount of energy to counteract large initial errors or disturbances, the actuators will inevitably saturate. This saturation breaks the assumptions of unconstrained control design, often leading to severe performance degradation, limit cycles, or instability. Therefore, designing a controller that merely stabilizes the system mathematically is insufficient; the control action must be structurally bounded to ensure it rigorously respects the physical saturation limits of the actuators under all operating conditions.
Driven by the strict necessity to maintain control signals within these physical limits while effectively managing unmodeled dynamics, the control community has continuously evolved its methodologies. The enduring challenge is to find an optimal balance between transient performance, robustness, and control effort constraints without introducing excessive computational complexity. Historically, early efforts to address the bounded stabilization of integrator chains focused heavily on nonlinear structural modifications of the state feedback.
One of the most significant early contributions to this problem was made by Teel [6], who proposed nested saturation functions for the global stabilization of chains of integrators with bounded control inputs, providing a proof of global stability using a nonlinear combination of saturation functions and linear feedback. This work became an important reference, motivating a broad line of research on bounded controllers for integrator chains. Subsequent studies extended Teel’s framework in several directions: studies for both linear [7,8] and nonlinear [9,10] systems demonstrated stability using bounded controllers. Moreover, Laporte et al. [11] addressed the global stabilization of integrator chains by means of bounded feedbacks with explicit constraints on the successive time derivatives of the control signal, ensuring smooth control actions beyond what classical nested saturation alone guarantees. More recently, Saeed et al. [12] proposed a dual-mode scheme combining Model Predictive Control with nested saturation feedback, achieving high-performance global stabilization of high-order integrator chains even in the presence of input disturbances. From the perspective of practical implementations, Chitour et al. [13] developed adaptive higher-order sliding mode controllers for the practical stabilization of perturbed integrator chains with unknown disturbance bounds, demonstrating that Lyapunov-based adaptive designs can be extended to handle unknown uncertainty levels.
The stabilization problem becomes considerably more challenging when external disturbances and model uncertainties are present. Linear control strategies, such as the Linear Quadratic Regulator (LQR), offer straightforward implementation and well-established theoretical foundations; however, their performance typically degrades under model uncertainties or varying operating conditions unless extensive retuning is performed [5]. This limitation has driven the development of robust and nonlinear control approaches capable of handling uncertainty more effectively.
Among robust nonlinear techniques, Sliding Mode Control (SMC), introduced by Utkin [14], has been extensively applied to integrator chain systems due to its ability to guarantee finite-time stability and strong robustness against bounded disturbances. Slotine and Sastry [15] established foundational results on tracking control using sliding surfaces. A persistent drawback of classical SMC, however, is the chattering phenomenon, which generates high-frequency oscillations in the control output and may excite unmodeled dynamics. Levant [16] provided important results on sliding order and accuracy in SMC that influenced subsequent chattering reduction strategies. Higher-order sliding mode algorithms, reviewed in [17], alleviate chattering by confining the discontinuous switching action to higher-order derivatives of the sliding variable, at the cost of requiring higher-order state derivatives and increasing sensitivity to measurement noise. More recently, smooth sliding mode formulations have been proposed as an alternative: Gaber [18] introduced an observer-free sliding mode approach that yields smooth, bounded control signals by construction, demonstrating robustness on benchmark nonlinear systems without requiring state observers or higher-order derivatives. Despite these advances, smooth approximations of SMC often trade off robustness for smoothness, and may not fully preserve the finite-time convergence guarantees of discontinuous implementations.
Neural-network-based control has emerged as a powerful alternative for uncertain nonlinear systems, owing to the universal approximation capability of neural networks. Early foundational contributions by Narendra and Parthasarathy [19] demonstrated the viability of neural networks for the identification and control of nonlinear dynamical systems. Sanner and Slotine [20] proposed Gaussian-network-based direct adaptive control for nonlinear systems, while Polycarpou [21] developed a Lyapunov-based adaptive neural control scheme with explicit stability guarantees. In robotic applications, Lewis et al. [22] showed that online weight adaptation combined with robustifying terms can guarantee trajectory tracking and bounded neural network weights.
These results motivated a broader class of neuroadaptive control strategies for uncertain nonlinear systems. Volyanskyy et al. [23] proposed a neuroadaptive architecture capable of compensating nonlinear uncertainty without requiring persistent excitation, and Hayakawa et al. [24] presented a neural adaptive control framework with asymptotic stability guarantees for a class of nonlinear uncertain systems. From an applied perspective, online neural controllers have been implemented in underactuated systems such as quadrotors, where combined offline and online learning stages improve tracking performance under changing operating conditions [25]. Recent work has highlighted the value of simplified neural architectures for adaptive control: Saini et al. [26] proposed a minimalistic adaptive controller based on a single linear neuron, where stability and convergence rate are ensured through Lyapunov-based adaptive learning rates, demonstrating that complex multi-layer structures are not always necessary to achieve satisfactory control performance. Rai et al. [27] further proposed novel recurrent neural network architectures for dynamical system identification and adaptive control using the backpropagation optimization method, with Lyapunov-based stability analysis, illustrating continued interest in architectures that balance approximation power with implementation simplicity. Li et al. [28] developed adaptive fixed-time neural network tracking controllers for nonlinear interconnected systems, extending neural adaptive control to finite-time and fixed-time stability frameworks.
Despite these advances, many neural control strategies still rely on recursive designs, multiple adaptation loops, or plant-dependent structures, which may increase implementation complexity. This motivates the search for adaptive neural controllers that preserve bounded control action, reduce design burden, and still provide rigorous stability guarantees for canonical systems such as chains of integrators.
Another systematic approach for stabilizing uncertain nonlinear systems is Backstepping Control (BC), wherein the controller design is based on a recursive Lyapunov candidate function that ensures the derivative of the candidate function is negative definite at each step [29]. Ge and Wang [30] combined backstepping with neural networks to stabilize nonlinear systems in strict-feedback form with unknown functions, using neural networks as universal approximators to estimate unknown nonlinearities. Li et al. [31] extended this approach to ensure stability in the presence of unknown external disturbances. A major limitation of backstepping-based neural controllers, however, is the well-known “explosion of complexity” problem, where the recursive design generates increasingly complex expressions at each step, requiring as many adaptation laws as there are states in the system. To address this, Dynamic Surface Control (DSC) was introduced as a technique that uses first-order filters to propagate virtual control signals across design steps, thereby avoiding repeated differentiation [32,33]. Finite-time extensions of DSC with neural approximation have also been developed [34], and DSC-based approaches have been applied to discrete-time nonlinear systems [35]. Despite these advances, backstepping-based methods still require the design of an auxiliary controller for each state, which represents a significant computational burden in both design and real-time implementation.
The use of singular perturbation theory as a stability analysis tool for adaptive and nonlinear control systems has received sustained attention in the literature. The classical framework established by Kokotovic, Khalil, and O’Reilly [36] and further developed in [37,38,39] provides the theoretical foundation for decoupling fast and slow dynamics and independently analyzing the stability of each subsystem using Tikhonov’s Theorem. More recently, Rayguru et al. [40] proposed a singular perturbation-based adaptive strategy for bounded controller design in feedback linearizable systems, using high-gain dynamic controllers to enforce time-scale separation and facilitate dynamic inversion, with contraction theory used to prove stability beyond the restrictive range of the perturbation parameter. The same group [41] investigated a singular perturbation approach to saturated controller design with applications to wing rock suppression in aircraft, deriving explicit tracking error bounds in both the presence and absence of disturbances. These works demonstrate that singular perturbation theory, when combined with adaptive mechanisms, provides a principled method to achieve bounded and smooth control actions with rigorous stability guarantees, and motivate its use in the present work.
Despite the progress surveyed above, several limitations persist in the existing literature. Many neural adaptive control strategies rely on recursive structures that introduce the explosion of complexity problem. Bounded control approaches based on nested saturations achieve global stability but may exhibit slow transient performance under large initial conditions. Sliding mode controllers offer strong robustness guarantees but may introduce chattering, and their smooth approximations may compromise robustness properties. Linear controllers such as LQR are simple to implement but degrade under uncertainty. This persistent trade-off between structural simplicity, robustness, and implementability motivates the search for adaptive neural controllers that are structurally simple, produce smooth and bounded control actions, and still provide rigorous stability guarantees for canonical systems such as chains of integrators.
Motivated by these considerations, this work proposes a novel Adaptive Neural Control (ANC) scheme for the asymptotic stabilization of a chain of integrators. The proposed approach employs a smooth nonlinear controller based on the hyperbolic tangent function , with an adaptation law derived from the classical backpropagation algorithm. The controller utilizes a single-neuron structure, significantly reducing the number of adaptive parameters and the computational burden compared to multi-layer or recursive architectures. The stability analysis is conducted using singular perturbation theory and Tikhonov’s theorem, which requires a separation of time scales between the adaptation dynamics and the state dynamics. A sufficiently high learning rate induces this time-scale separation and casts the closed-loop system into the Standard Singular Perturbation Form. The convergence of the fast dynamics is established using Lyapunov analysis and LaSalle’s invariance principle., and the stability of the slow dynamics is guaranteed via the Routh-Hurwitz criterion applied to the reduced-order model. Explicit conditions on the learning rate and initial conditions are derived to characterize the region of attraction and guarantee asymptotic stability.
The main contributions of this paper are summarized as follows:
- A novel Adaptive Neural Control (ANC) based on a single neuron with a activation function is proposed for stabilizing integrator chain systems.
- Unlike classical neural adaptive control approaches based on backstepping, the proposed method requires only a single adaptation law, avoiding recursive controller construction and reducing implementation complexity.
- The adaptive dynamics are formulated within a singular perturbation framework, showing that a sufficiently large learning rate induces a two-time-scale structure that enables rigorous stability analysis.
- Using Tikhonov’s Theorem, it is proven that the closed-loop system achieves asymptotic stability within a defined region of attraction.
- The proposed ANC controller is validated through numerical simulations and compared with LQR, Nested Saturation, and Sliding Mode Control in an Inverted Pendulum on a Cart benchmark.
The remainder of this paper is organized as follows. Section 2 presents the problem formulation, control objective, main result, and the stability analysis using singular perturbation theory. Section 3 provides numerical simulations under different scenarios and comparative results against other control techniques. Finally, Section 4 is dedicated to conclusions and future work.
2. Materials and Methods
2.1. Problem Formulation and Control Objective
Consider a linear dynamical system represented by a chain of integrators of order n, described by the following state-space equations:
where is the system dimension and the control input must be bounded.
The main objective is to design an adaptive bounded control law that guarantees asymptotic stability to the origin for the system (1). Specifically, the controller must ensure that:
- All closed-loop signals remain bounded.
- The state vector converges to the origin, i.e., , with bounded input .
2.2. Adaptive Neural Control Strategy
In this section, an ANC scheme for stabilizing the chain of integrators system described in (1) is presented.
Theorem 1.
Consider the chain of integrators system defined in (1). Let control input be defined by the following equation:
where is the extended state vector and is the adaptive state gain vector; acts as control bias.
Let the adaptation law for the weights Ω be given by:
where is the learning rate and , .
If the learning rate η is large enough such that (defined formally in (6)) acts as singular perturbation parameter forcing the sliding surface
converges rapidly to a neighborhood of zero, let us define the equivalent control effort required to remain on the slow manifold as:
Consequently, when , the actual control input approaches the equivalent control:
Proof.
In order to apply singular perturbation theory to the proposed adaptive control scheme (2), (3) the following assumptions are introduced.
- Assumption 1: Smoothness of nonlinear mappingsThe nonlinear activation function used in the control law (2) is continuously differentiable with respect to both the extended state vector X and the adaptive parameter vector . Consequently, the closed-loop vector field is continuously differentiable.
- Assumption 2: Bounded activation functionThe hyperbolic tangent function and its derivative satisfy and , for all . Therefore, the applied control signal and its derivative remain bounded.
- Assumption 3. Admissible Initial ConditionsThe initial state vector belongs to a compact set such that the control input is not saturated. The compact set will be defined later.
- Assumption 4: Local Lipschitz continuityThe closed-loop vector field of the adaptive system is locally Lipschitz with respect to the variables , ensuring the existence and uniqueness of solutions.
- Assumption 5: Uniqueness of Equivalent Control on the Slow ManifoldFor fixed values of the slow variables x within the admissible set , the algebraic equation defines the slow manifold. While there may exist multiple parameter configurations that satisfy this condition, the mapping onto the control space yields a unique, isolated quasi-steady-state solution for the equivalent control effort .
□
2.3. Stability Analysis via Singular Perturbation Theory
To analyze the system using singular perturbation theory, the learning rate is used to introduce the small parameter
For sufficiently large values of , it follows that , which creates a separation between the fast adaptation dynamics and the slower system dynamics. Using this definition, the adaptive update law (3) can be rewritten as
Consequently, the closed-loop system can be expressed in the Standard Singular Perturbation Form (SSPF) [17,37] as:
Remark on Tikhonov’s Applicability: Although the dimension of the fast variable implies that the manifold constraint does not yield a unique, isolated root in the parameter space, the foundational requirements of Tikhonov’s Theorem are preserved for the state trajectories. This is because the slow subsystem dynamics depend entirely on the mapped control input , rather than the individual weight parameters . The algebraic constraint defines a unique, isolated quasi-steady state for the control signal (). Therefore, by projecting the fast adaptation dynamics onto the scalar sliding surface s, the apparent non-uniqueness in the weight space is circumvented, ensuring that the slow dynamics are driven by a uniquely defined reduced-order model.
If is chosen sufficiently large (), system (8) exhibits a two-time-scale property. This allows the use of Tikhonov’s Theorem to decouple the analysis into two separate subsystems [38,39]:
- Slow subsystem (Reduced Model), governed by state dynamics (8a) and (8b) when the fast variables have reached their quasi-steady state.
- Fast subsystem (Boundary Layer), governed by weight dynamics (8c) considering the slow states as frozen parameters.
According to Tikhonov’s Theorem for singularly perturbed systems, consider a system of the form
where is a small positive parameter. If the following conditions hold:
- the reduced system obtained by solving is asymptotically stable
- the boundary layer system is asymptotically stable uniformly with respect to the slow variables x
- the vector fields and are sufficiently smooth
then there exists such that for all the trajectories of the full system remain close to the reduced solution and inherit its stability properties.
Therefore, under Assumptions 1–5, the stability of the proposed control scheme is analyzed using Tikhonov’s Theorem for singularly perturbed systems.
2.3.1. Existence of Isolated Roots and Fast Dynamics Stability
To analyze the fast dynamics (8c), the boundary-layer time scale is introduced as
the chain rule yields
Substituting the time derivative with respect to t into the adaptation dynamics in (8c) yields
In this fast time scale, the slow variables X are considered frozen parameters. Let us define the sliding surface s as follows:
Therefore, the sliding surface evolves strictly as a function of the fast time scale through the adaptation of the weights . In order to analyze the convergence of the fast dynamics, The following Lyapunov function candidate is proposed:
To guarantee asymptotic stability, derivative of the Lyapunov candidate with respect to , denoted as , must be negative definite. Establishing this condition ensures asymptotic convergence of the fast dynamics towards the slow manifold. This implies that sliding surface converges exponentially to zero, leading to the equivalent relation
2.3.2. Derivative of Lyapunov Candidate
To verify the asymptotic stability condition, time derivative of the Lyapunov candidate function (12) with respect to was calculated. Accordingly with the described above, evolve in time scale while X are considered as frozen parameters. Applying the chain rule, time derivative is given by:
Based on the definitions in (2) and (11), the sliding surface is a function of whereby evolve with respect to time scale . Differentiating the sliding surface (11) with respect to , recalling that the slow variables X are treated as frozen parameters so that is a constant in the fast time scale (hence ), the following equation is obtained:
Let denote the derivative of the activation function. Assuming X comprises slow state variables which remain constant with respect to the time scale , the term simplifies to . Substituting (15) into (14) yields:
To ensure that , the update law for the parameters is designed based on gradient descent algorithm commonly used in neural networks. The update law is proposed as
Accordingly on chain rule derived in the backpropagation algorithm:
where is the learning rate. System (18) is same as the one proposed in (3) but in compact form. Substituting (18) into (16), time derivative of the Lyapunov function becomes:
where denotes the norm. Since squared terms are non-negative, it follows that . Therefore, the Lyapunov function is non-increasing and the fast subsystem is Lyapunov stable. Furthermore, since is lower-bounded by zero, it converges to a finite limit as .
It is important to note that the derivative of the Lyapunov function in (19) does not depend explicitly on the particular values of the slow variables X except through the bounded term . Since the initial conditions (Assumption 3) and the vector field is locally Lipschitz ensuring no finite-time escape (Assumption 4), implies that remains bounded.
Therefore, the equilibrium of the fast subsystem is asymptotically stable uniformly with respect to the slow variables X. This satisfies the uniform stability condition required for the application of Tikhonov’s Theorem.
To demonstrate asymptotic convergence of the sliding surface , the LaSalle Invariance Principle [37] is invoked. Since the boundary-layer system is autonomous in the -scale (with slow variables X treated as frozen parameters), and is a continuously differentiable, positive definite, radially unbounded function satisfying , all conditions for LaSalle’s theorem are satisfied.
Define the set where the derivative vanishes:
By LaSalle’s Invariance Principle, every trajectory converges to the largest invariant set contained in . It remains to characterize .
Lemma 1.
The largest invariant set of the boundary-layer system (8c) is .
Proof.
To demonstrate that and exclude the possibility of while , we must prove the boundedness of the weight vector and show that has a positive lower bound.
Since the slow variables X act as frozen parameters in the boundary-layer time scale, let us analyze the scalar variable . Multiplying the adaptation law (8c) by , we obtain the explicit dynamics of z:
Since the initial conditions are restricted to the region of attraction (Assumption 3), it is strictly guaranteed that the equivalent control effort satisfies . Consequently, there exists a unique, finite scalar value such that .
The scalar differential equation for z has a unique stable equilibrium at . Because the term for all finite z, the trajectory strictly and asymptotically converges to the finite limit .
Since , it follows that the derivative of the activation function converges to a strictly positive constant:
This guarantees that is bounded away from zero. Furthermore, since the adaptation law restricts the update of entirely to the direction of the constant vector X, and the projection converges to a finite value, it follows that the parameter vector remains bounded for all .
With having a positive lower bound and being bounded, the invariant set condition (for ) can only be satisfied if . Therefore, the largest invariant set is definitively , and by LaSalle’s Invariance Principle:
□
This convergence ensures that the fast dynamics settle onto the slow manifold, so the algebraic constraint of the singular perturbation model is satisfied asymptotically, yielding the equivalent control:
This concludes the stability analysis of the fast subsystem.
2.3.3. Stability Analysis of Slow Dynamics
As demonstrated in preceding subsection, the adaptive law defined in (3) ensures that fast dynamics are stable and sliding surface (11) converges asymptotically to zero (). According to singular perturbation theory, once the fast transients (boundary layer) decay, the system operates on the slow manifold. Consequently, control input approaches to equivalent control effort defined as .
Substituting this equivalent control into slow subsystem dynamics (8a) and (8b) yields following reduced-order model:
This system can be expressed in state-space form as matrix A is given in the companion form:
The stability of the reduced slow dynamics is determined by the eigenvalues of A. The characteristic polynomial of the matrix is given as:
Applying Routh-Hurwitz stability criterion, the origin of slow subsystem is asymptotically stable provided that the coefficients satisfy the necessary and sufficient conditions for stability. Specifically, parameters must be selected as positive constants such that all roots of (26) lie strictly in the left-half complex plane. Therefore, the reduced-order slow dynamics described in Equations (8a) and (8b) are globally asymptotically stable. It is important to note that this result applies to the reduced-order model; the asymptotic stability of the complete closed-loop system is local.
2.3.4. Stability for Complete System
The analysis presented in preceding subsections establishes two key properties:
- The reduced-order model (slow dynamics), described by (24), is asymptotically stable if parameters satisfy the Routh-Hurwitz criterion.
Since the reduced slow subsystem is asymptotically stable and the boundary layer subsystem is uniformly asymptotically stable with respect to the slow variables, all conditions required by Tikhonov’s Theorem are satisfied under Assumptions 1–5. By definition of , a sufficiently small corresponds to a high learning rate in the adaptive control law.
2.3.5. Region of Attraction
Since the control input is generated by a hyperbolic tangent activation function, , the applied control signal is structurally bounded by unity, i.e., . To remain on the slow manifold, the equivalent control effort must be realizable by the controller. If , the adaptation law saturates and the sliding surface may not converge to zero to guarantee stability.
While the condition ensures the control is unsaturated at a given instant which is not strictly forward invariant. Due to transient overshoot, trajectories starting within this region could temporarily exit it, causing actuator saturation.
To define the region of attraction as a positively invariant set, consider a Lyapunov function for the asymptotically stable reduced-order system , where A is the companion matrix defined previously, and is the solution to the algebraic Lyapunov equation for any given . The region of attraction is defined as the largest invariant level set completely inscribed within the unsaturated region (Assumption 3):
Because is a positively invariant set for the slow dynamics, any trajectory originating inside will remain inside it for all , guaranteeing that the required control effort never exceeds unity. Therefore, the local asymptotic stability result derived by Tikhonov’s Theorem is valid for initial conditions .
3. Numerical Simulations and Results
This section presents the simulation results obtained to evaluate the performance of the proposed adaptive neural controller. The simulations illustrate the stabilization capability of the method and provide insight into the transient and steady-state behavior of the closed-loop system.
Specifically, the simulations focus on the following aspects:
- Nominal Performance: Verifying the asymptotic convergence of the system states to the origin when the initial conditions satisfy the region of attraction constraint defined in (27).
- Region of Attraction and Saturation: Illustrating the limitations of the control scheme when initial conditions lie outside of set , leading to actuator saturation and potential instability.
In practice, selecting the learning rate involves a strict trade-off between adaptation speed and system robustness. While the singular perturbation analysis requires to be sufficiently large to guarantee the separation of time scales and asymptotic stability, an excessively high value is undesirable in physical implementations. A disproportionately large causes premature saturation of the actuators. Therefore, a practical tuning heuristic consists of initializing with a small positive value and iteratively increasing it. The optimal parameter is found when the adaptation is fast enough to minimize the tracking error without causing excessive control effort or oscillatory behavior in the transient response.
All simulations were performed using a third-order system () to provide a clear visualization of the multi-variable dynamics. Weights are initialized to zero to demonstrate the learning capability of adaptive law without prior knowledge. All simulations were carried out using Wolfram Mathematica software.
3.1. Example 1: Ideal Case
Consider a chain of integrators with three states (). The objective is to stabilize the system using adaptive neural controller proposed in Equation (3). Parameters , which determine the dynamics of the slow manifold, are selected to satisfy the Routh-Hurwitz stability criterion for reduced-order polynomial .
The parameters are chosen as:
which satisfies the stability condition , which ensures that slow dynamics are asymptotically stable.
Learning rate for adaptation laws is set to , ensuring a sufficiently small singular perturbation parameter . The initial weights of the neural network are set to .
To validate the controller within the region of attraction , the initial states are chosen as:
Substituting these values into the condition for defined in (27):
The summary of the simulation conditions can be found in Table 1.
Table 1.
Simulation parameters and performance metrics for Example 1 (Ideal Case).
Since the magnitude of equivalent control is , which is less than the unity saturation limit of function, the system starts within the region of attraction. This guarantees that the adaptive law can effectively drive the sliding surface , ensuring convergence to the slow manifold.
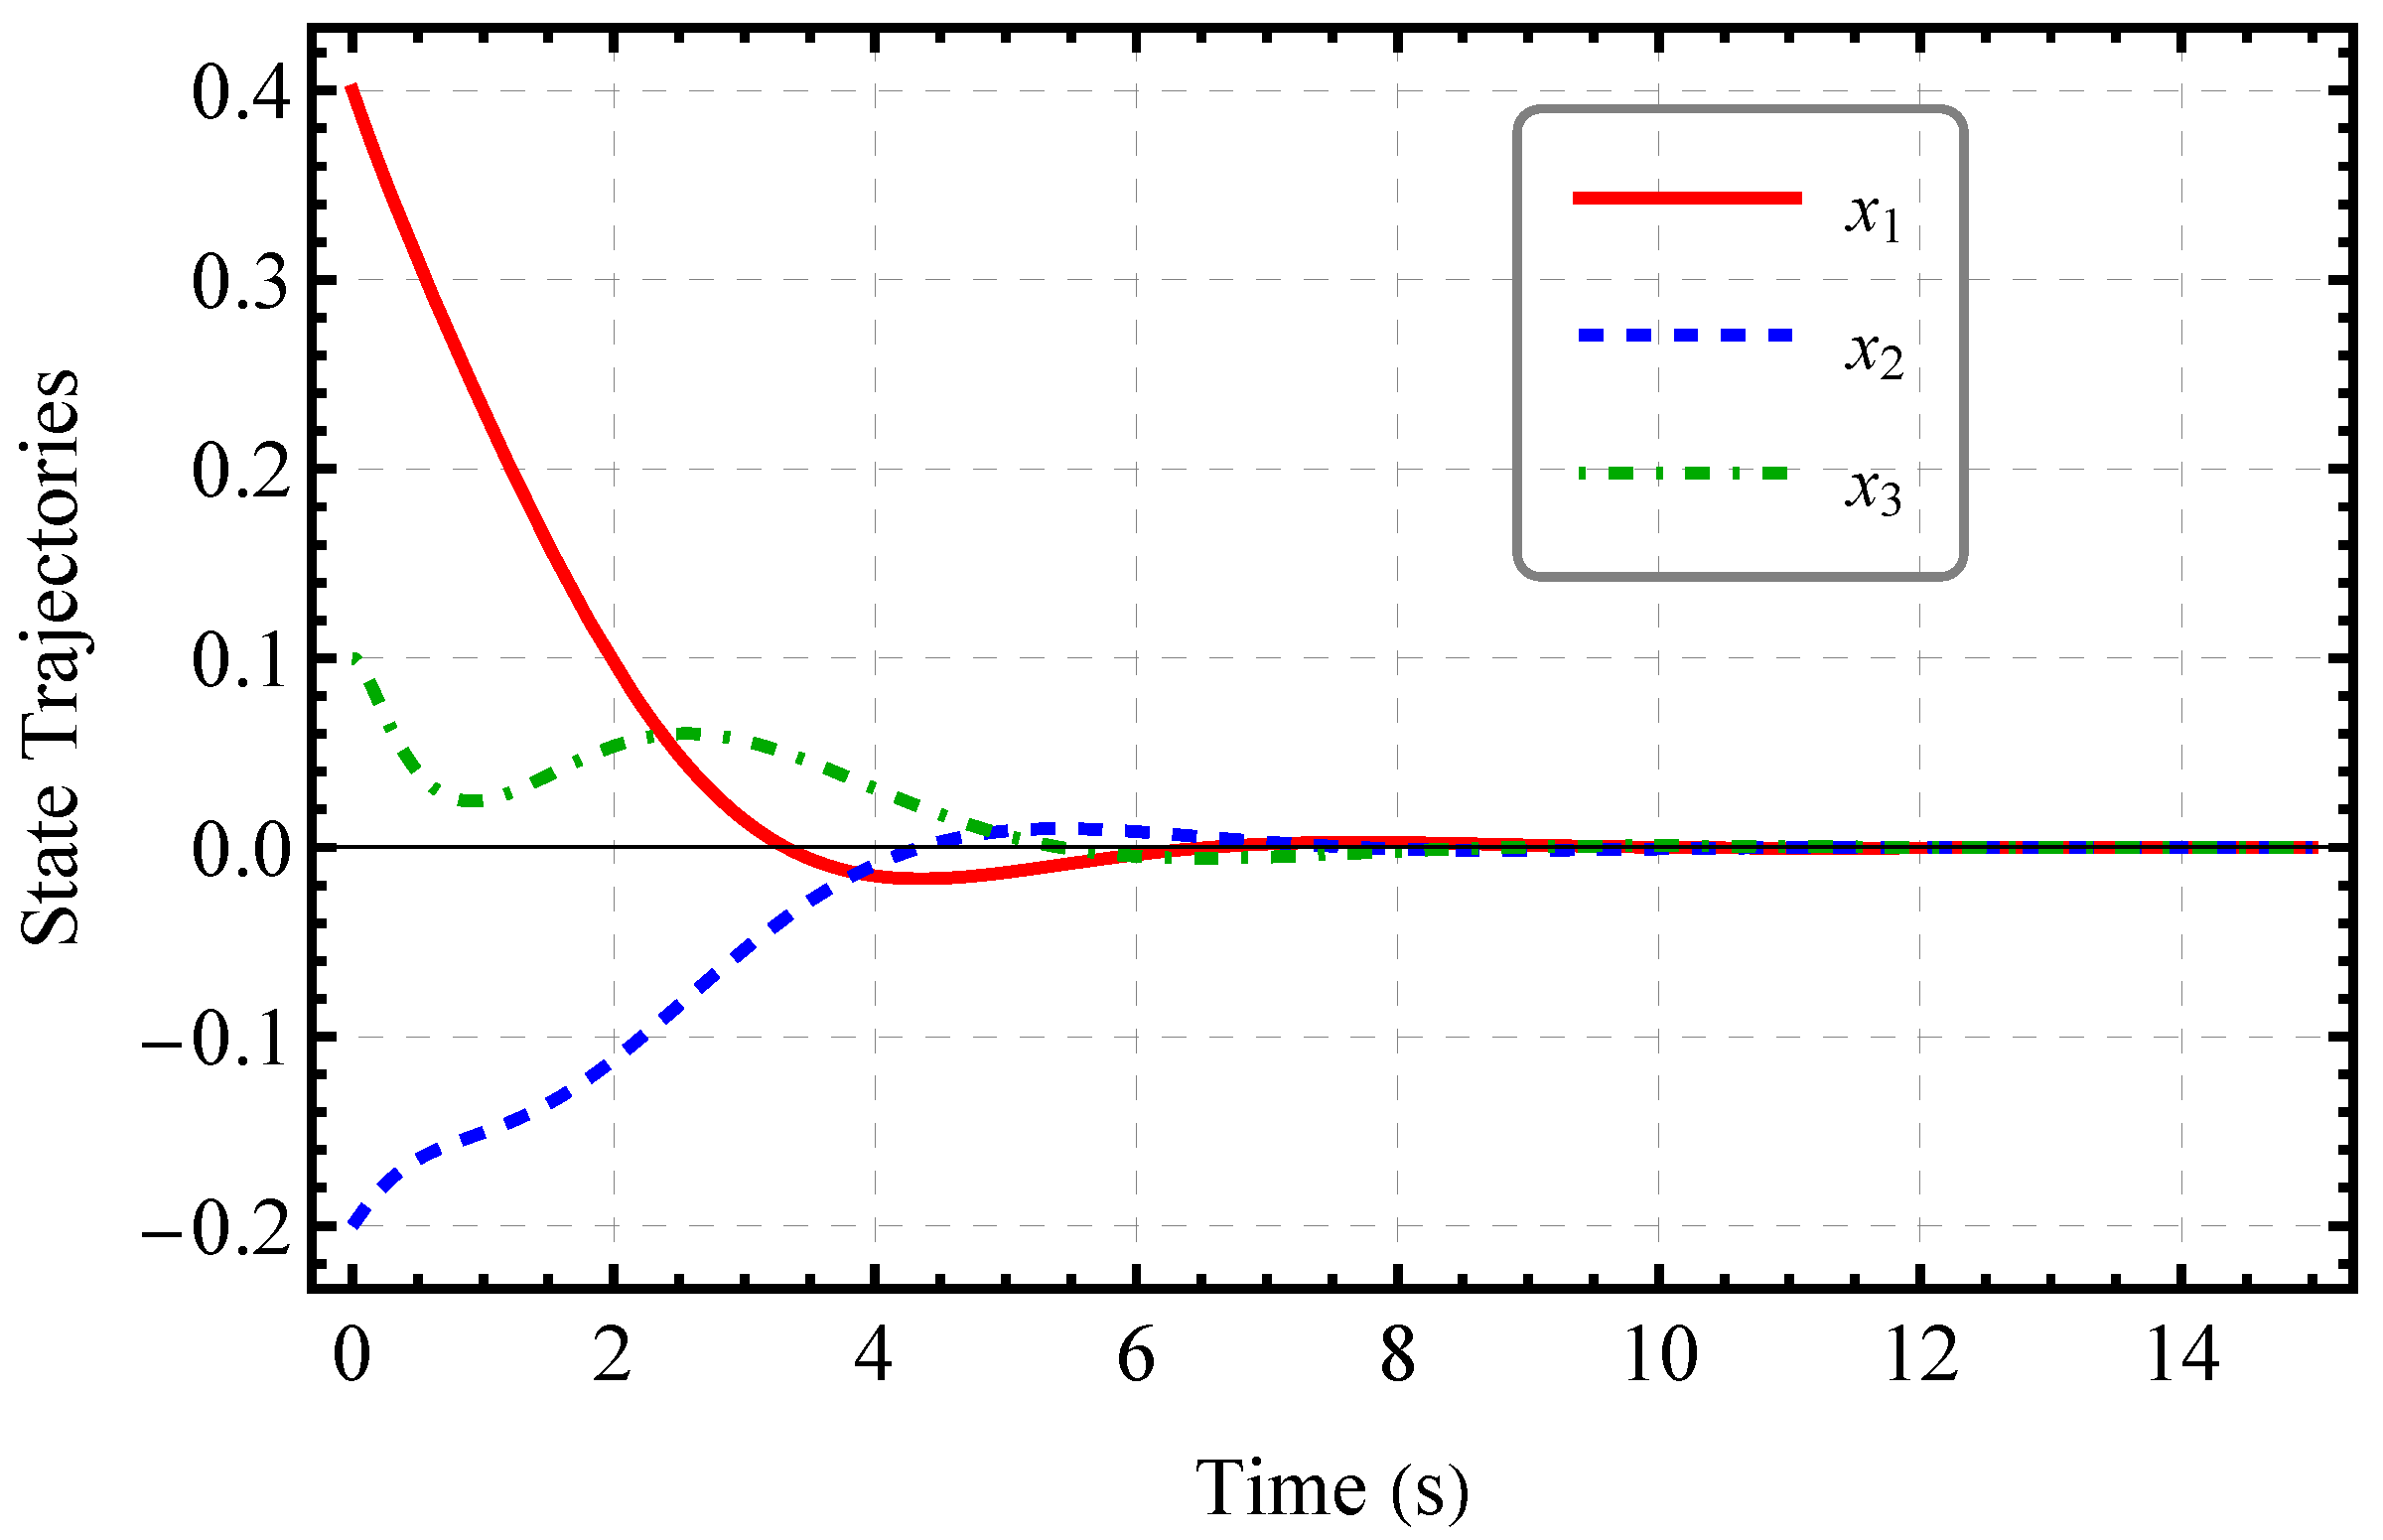
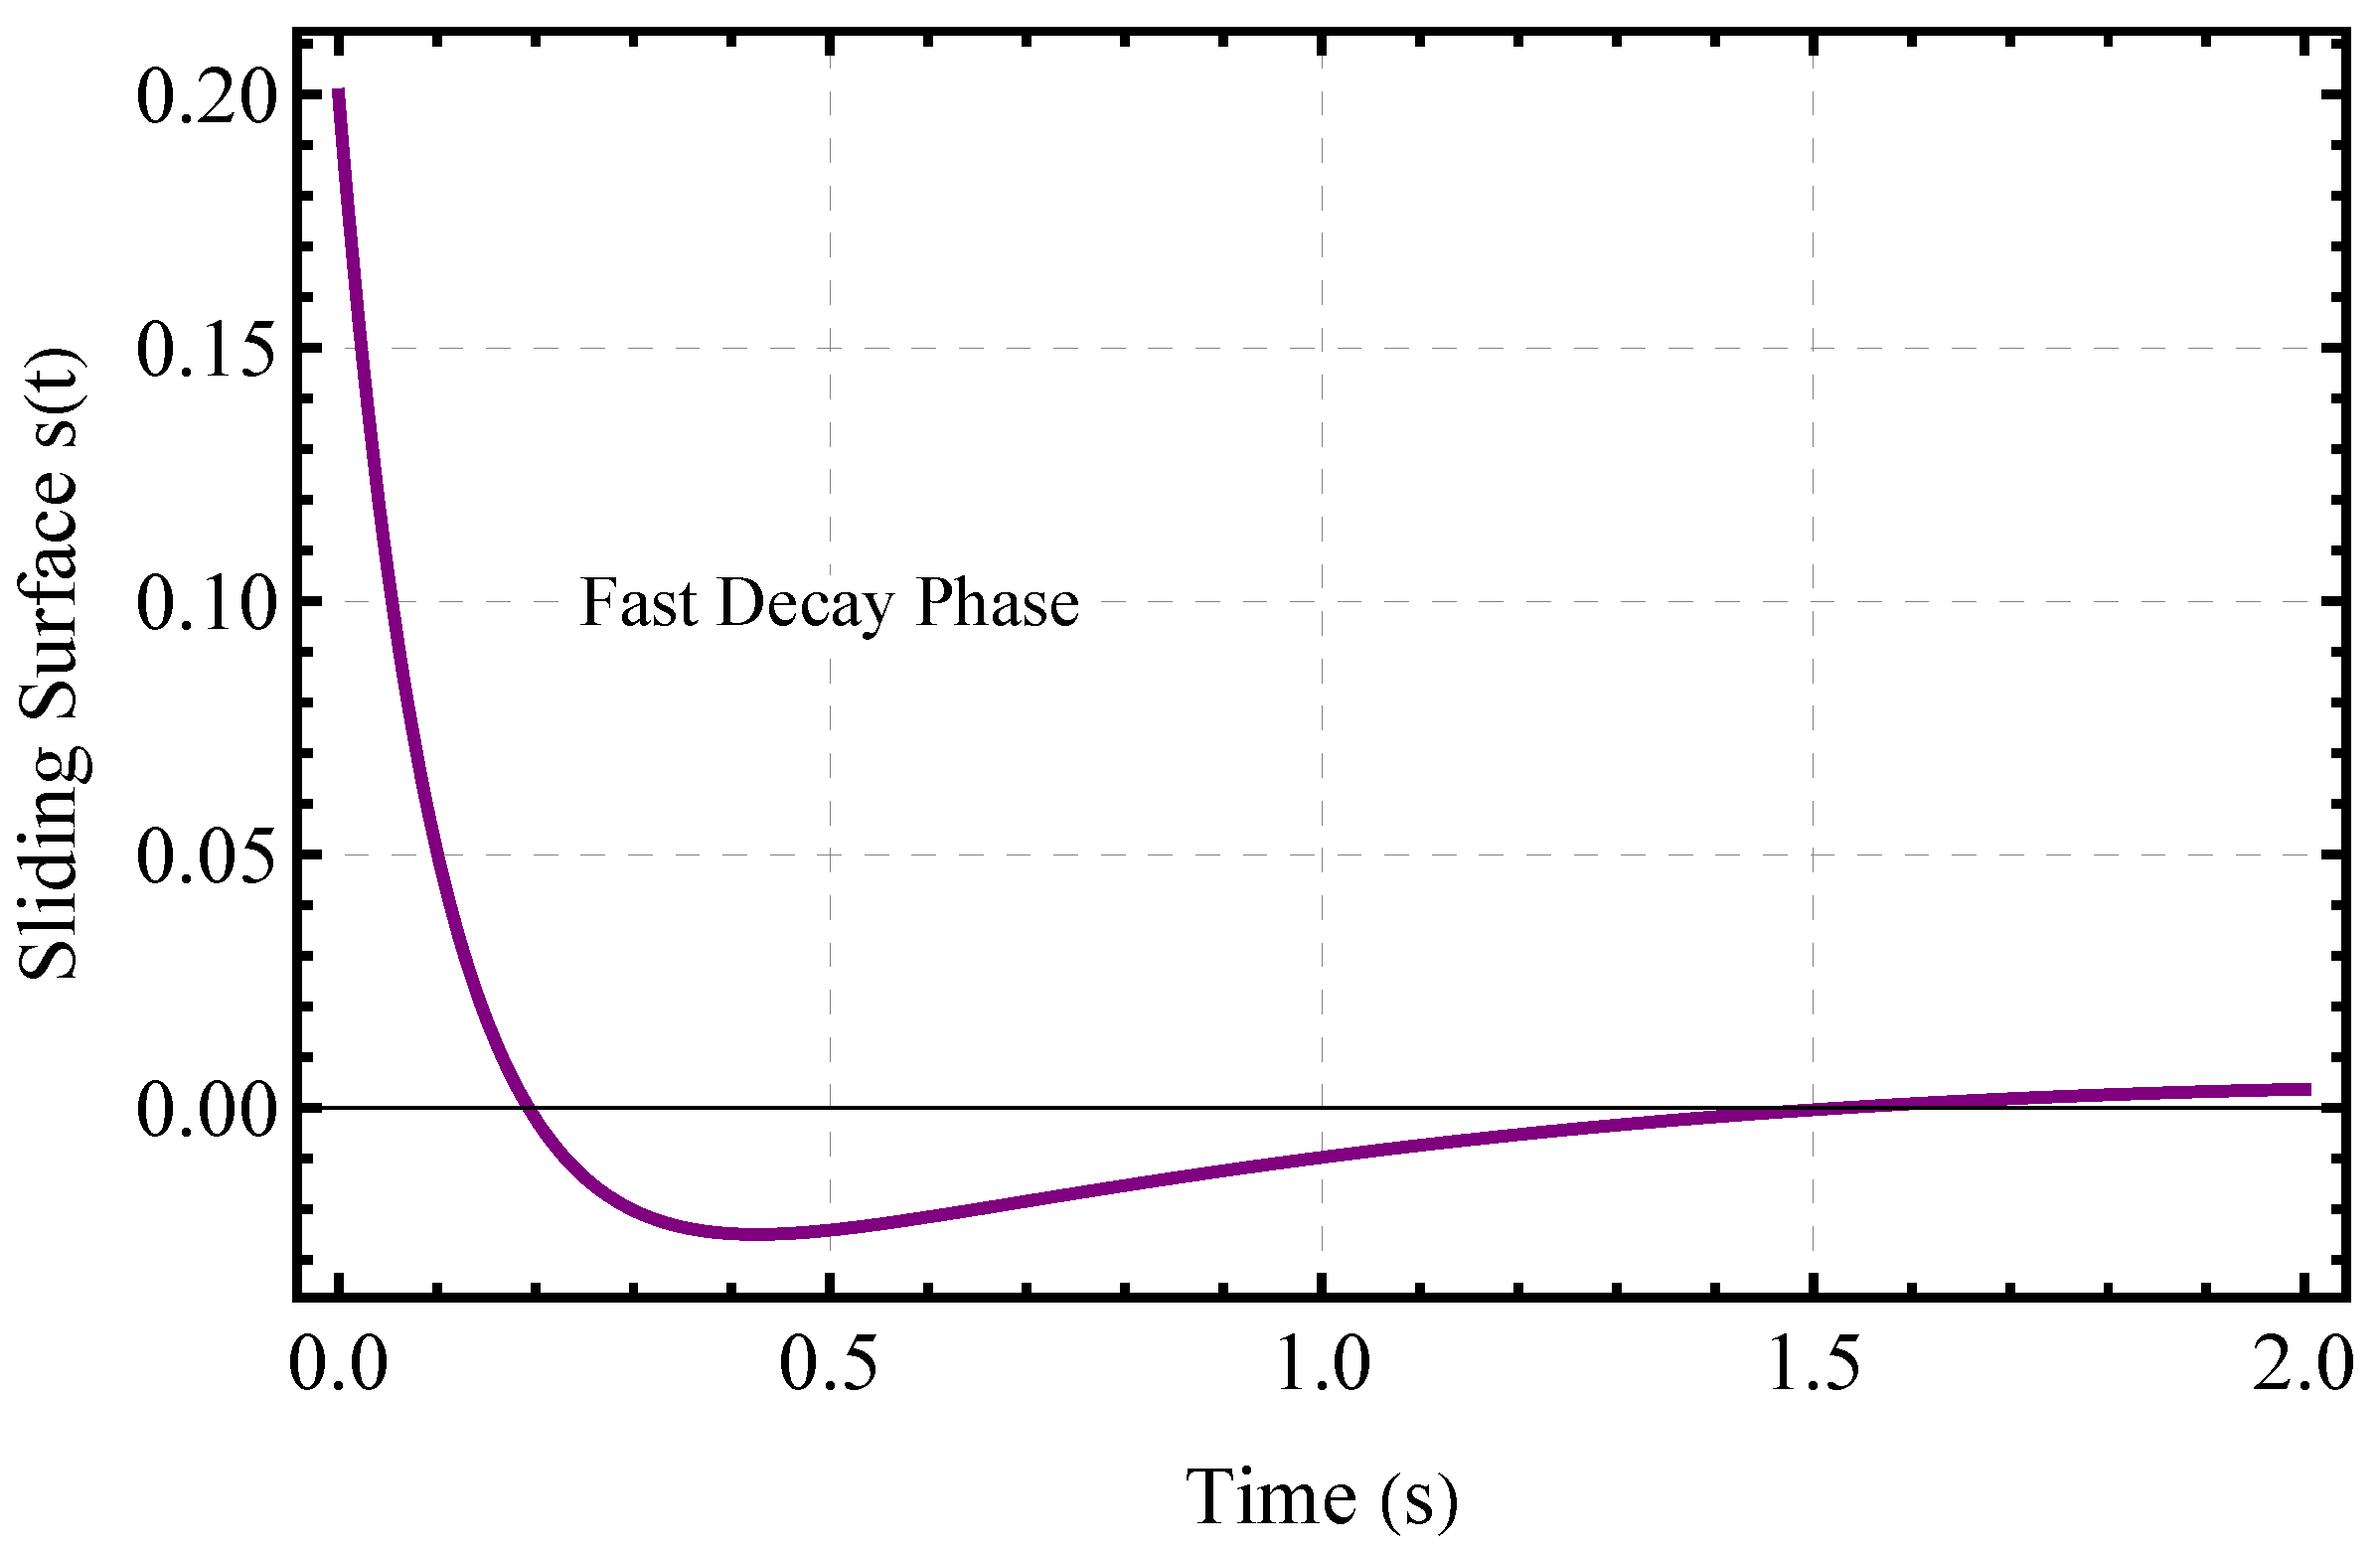
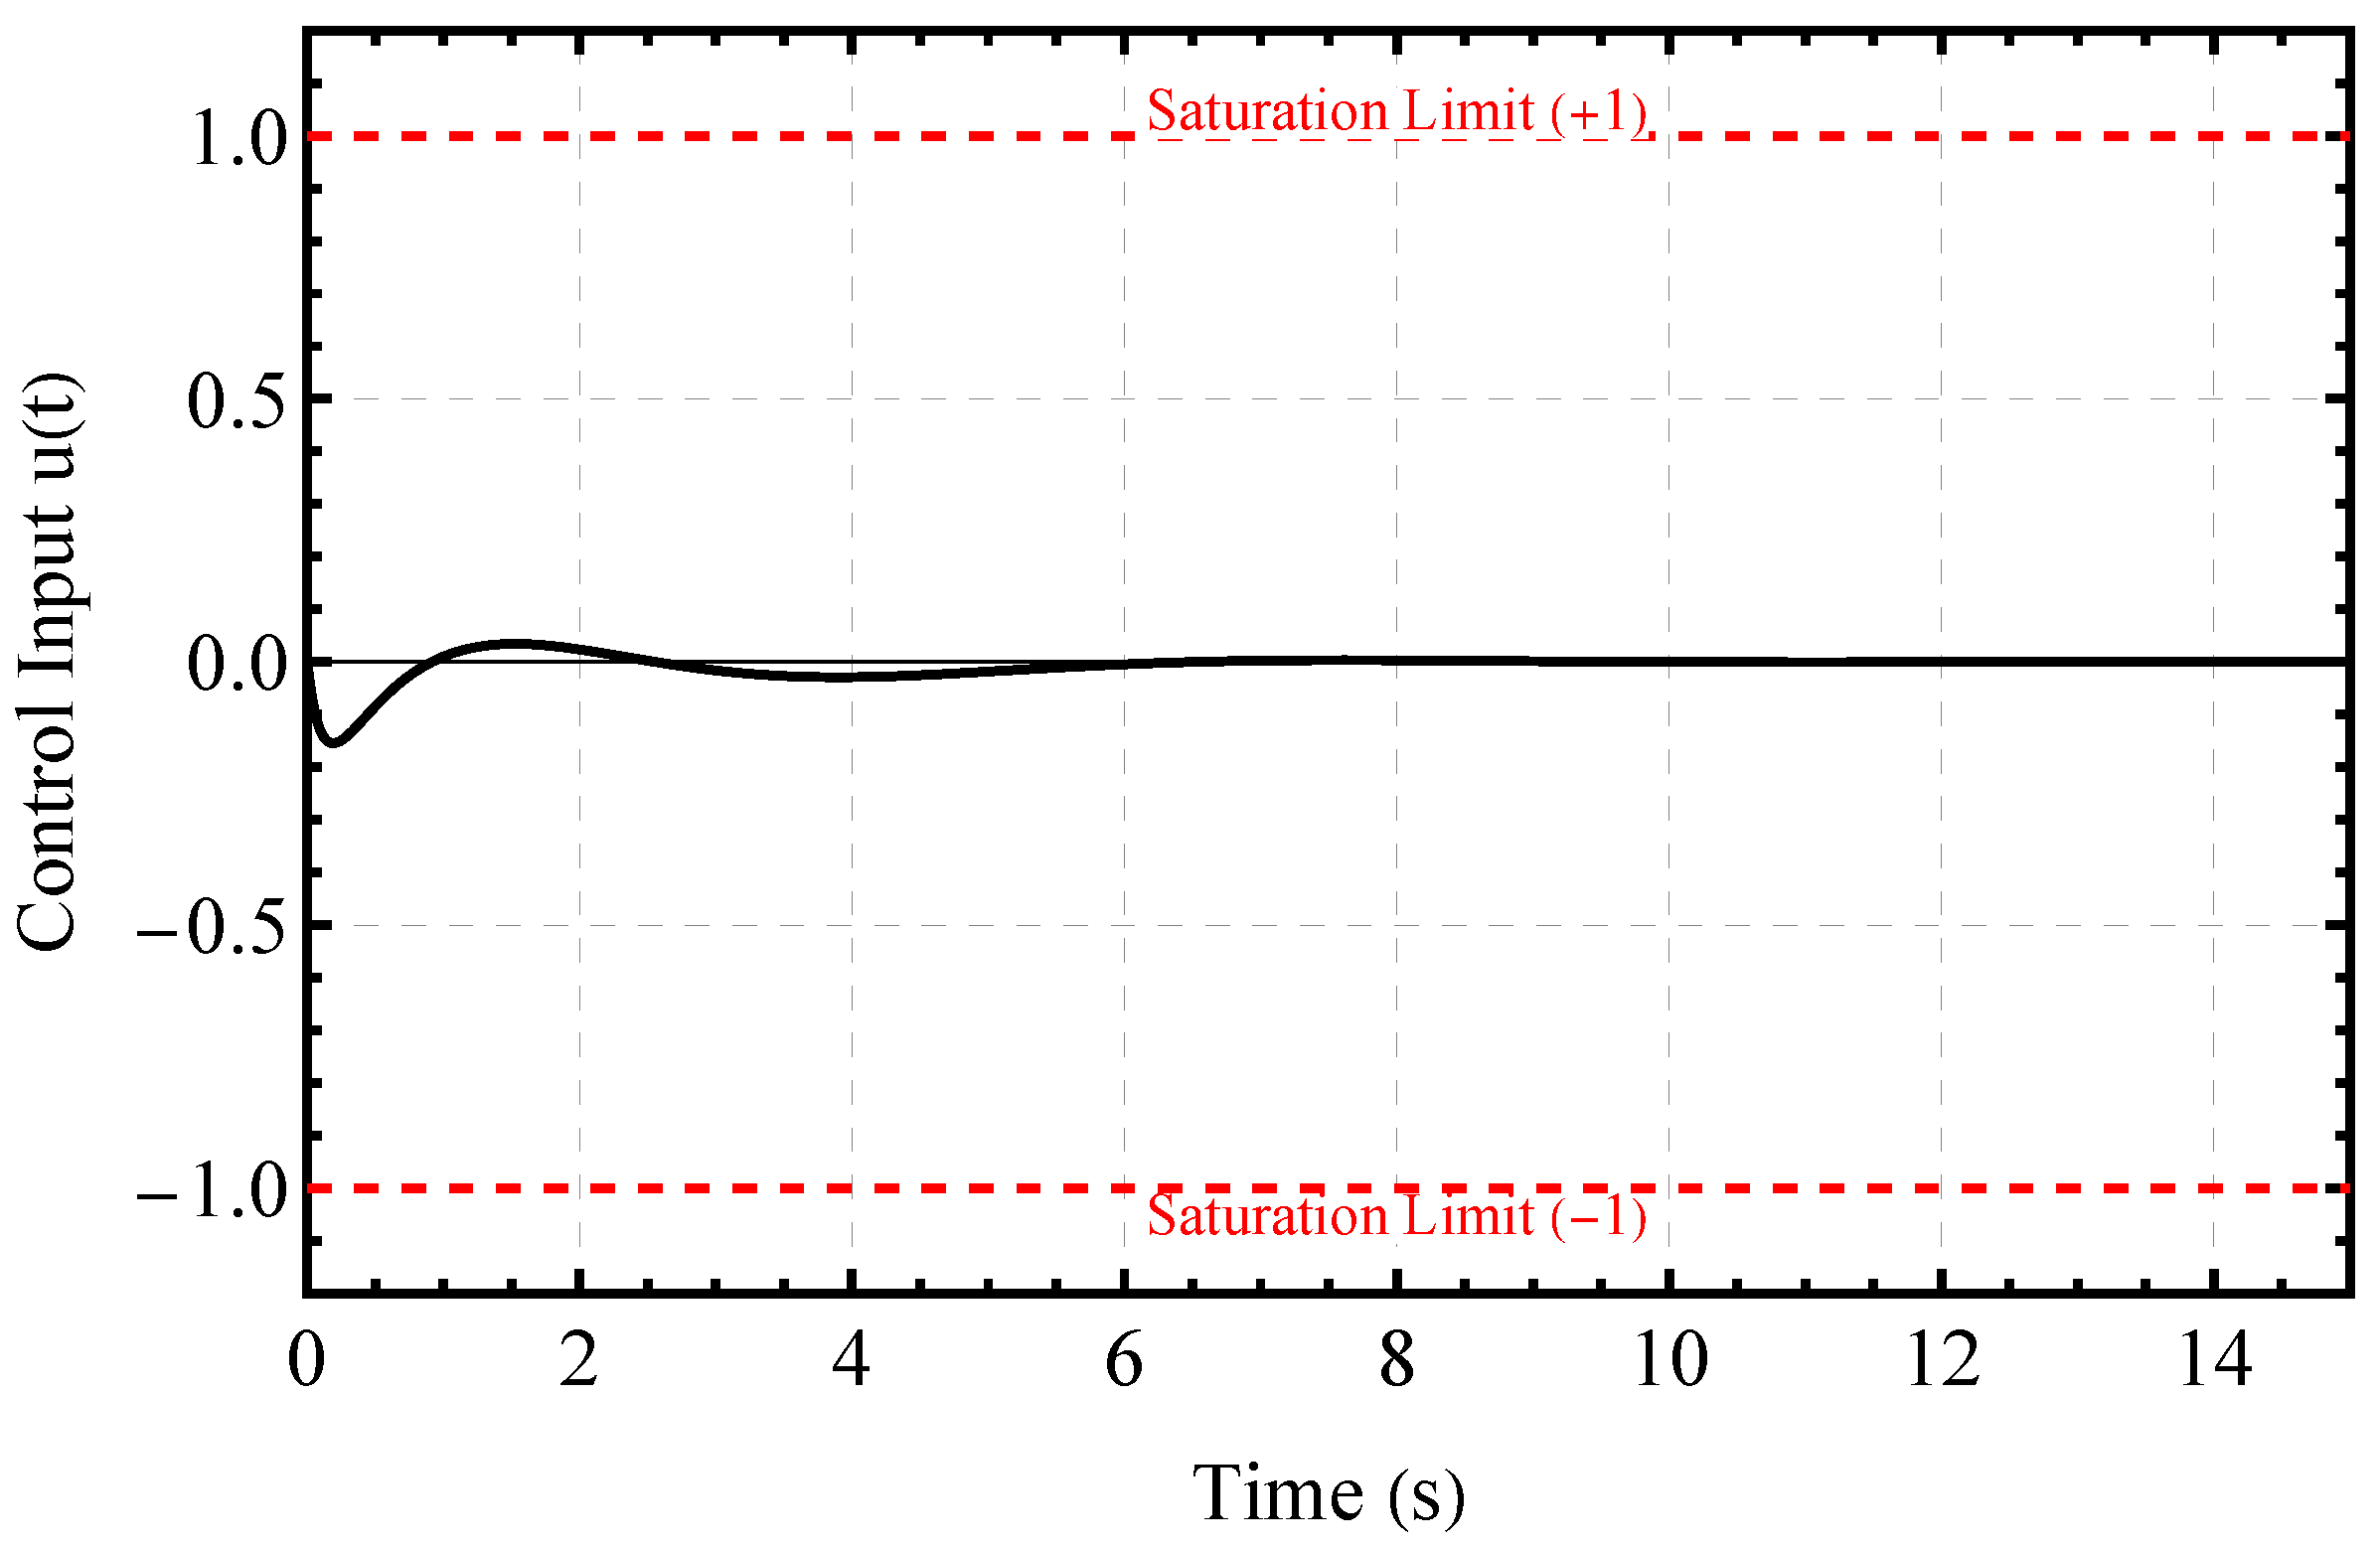
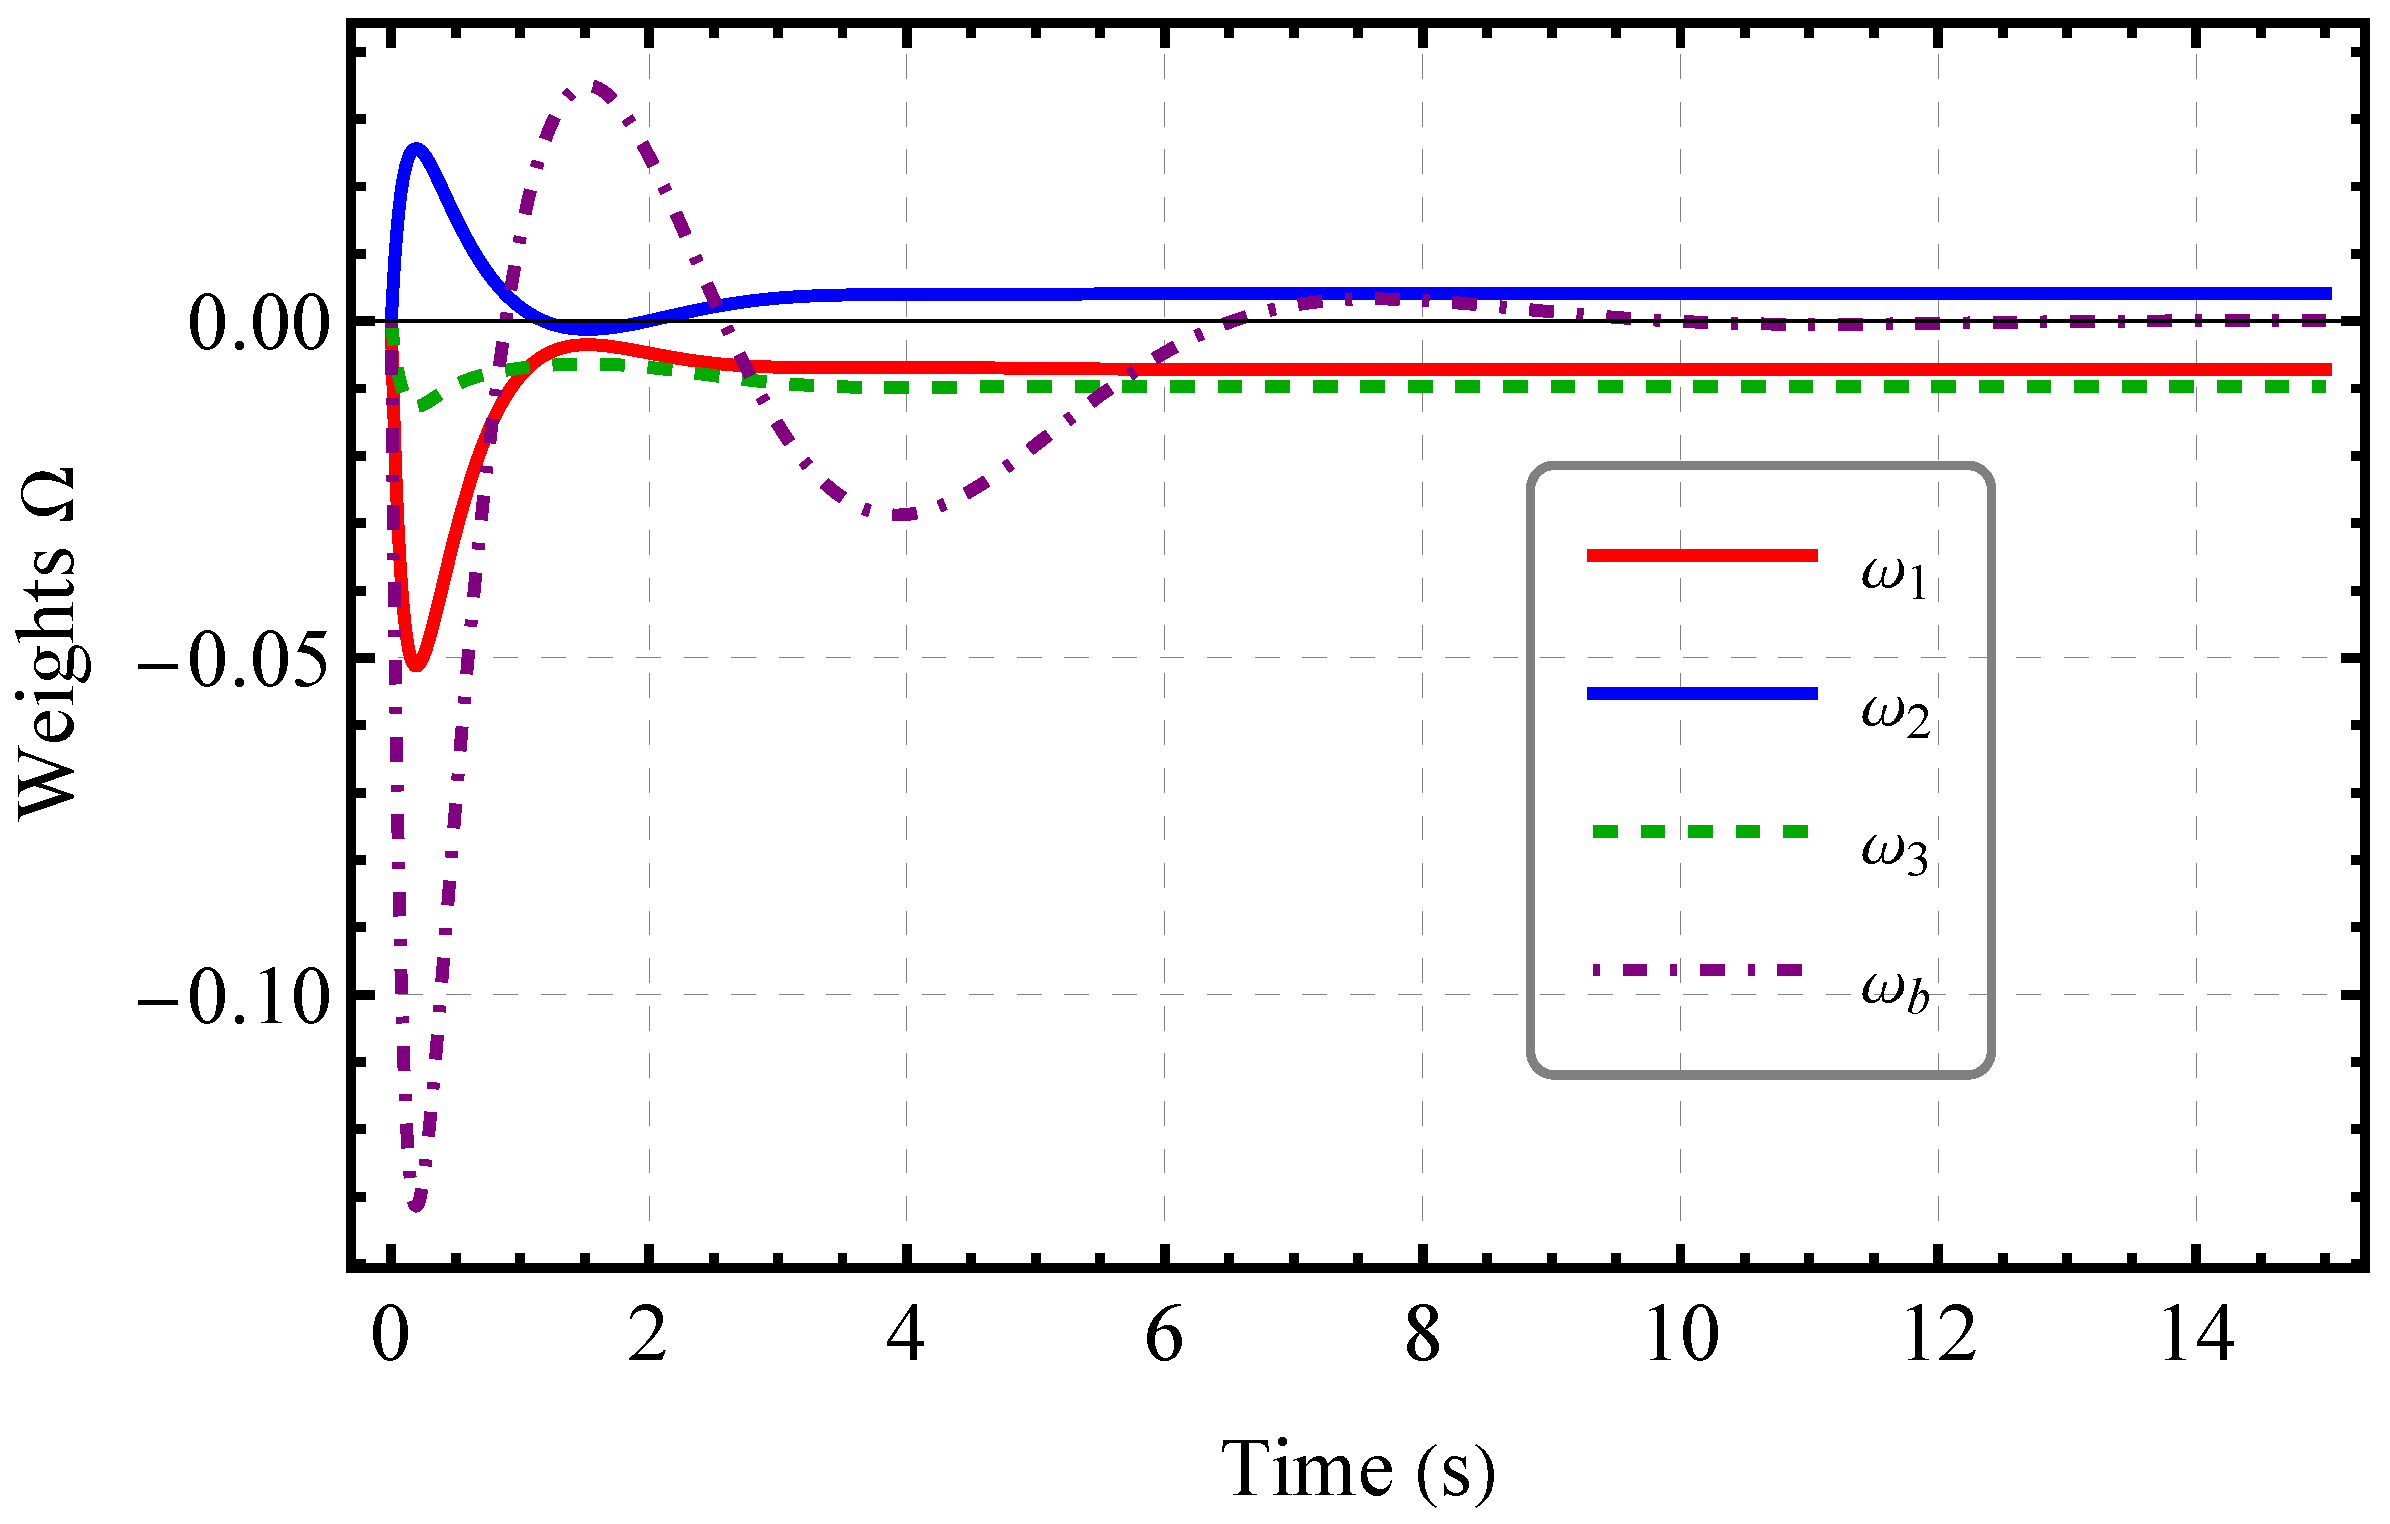
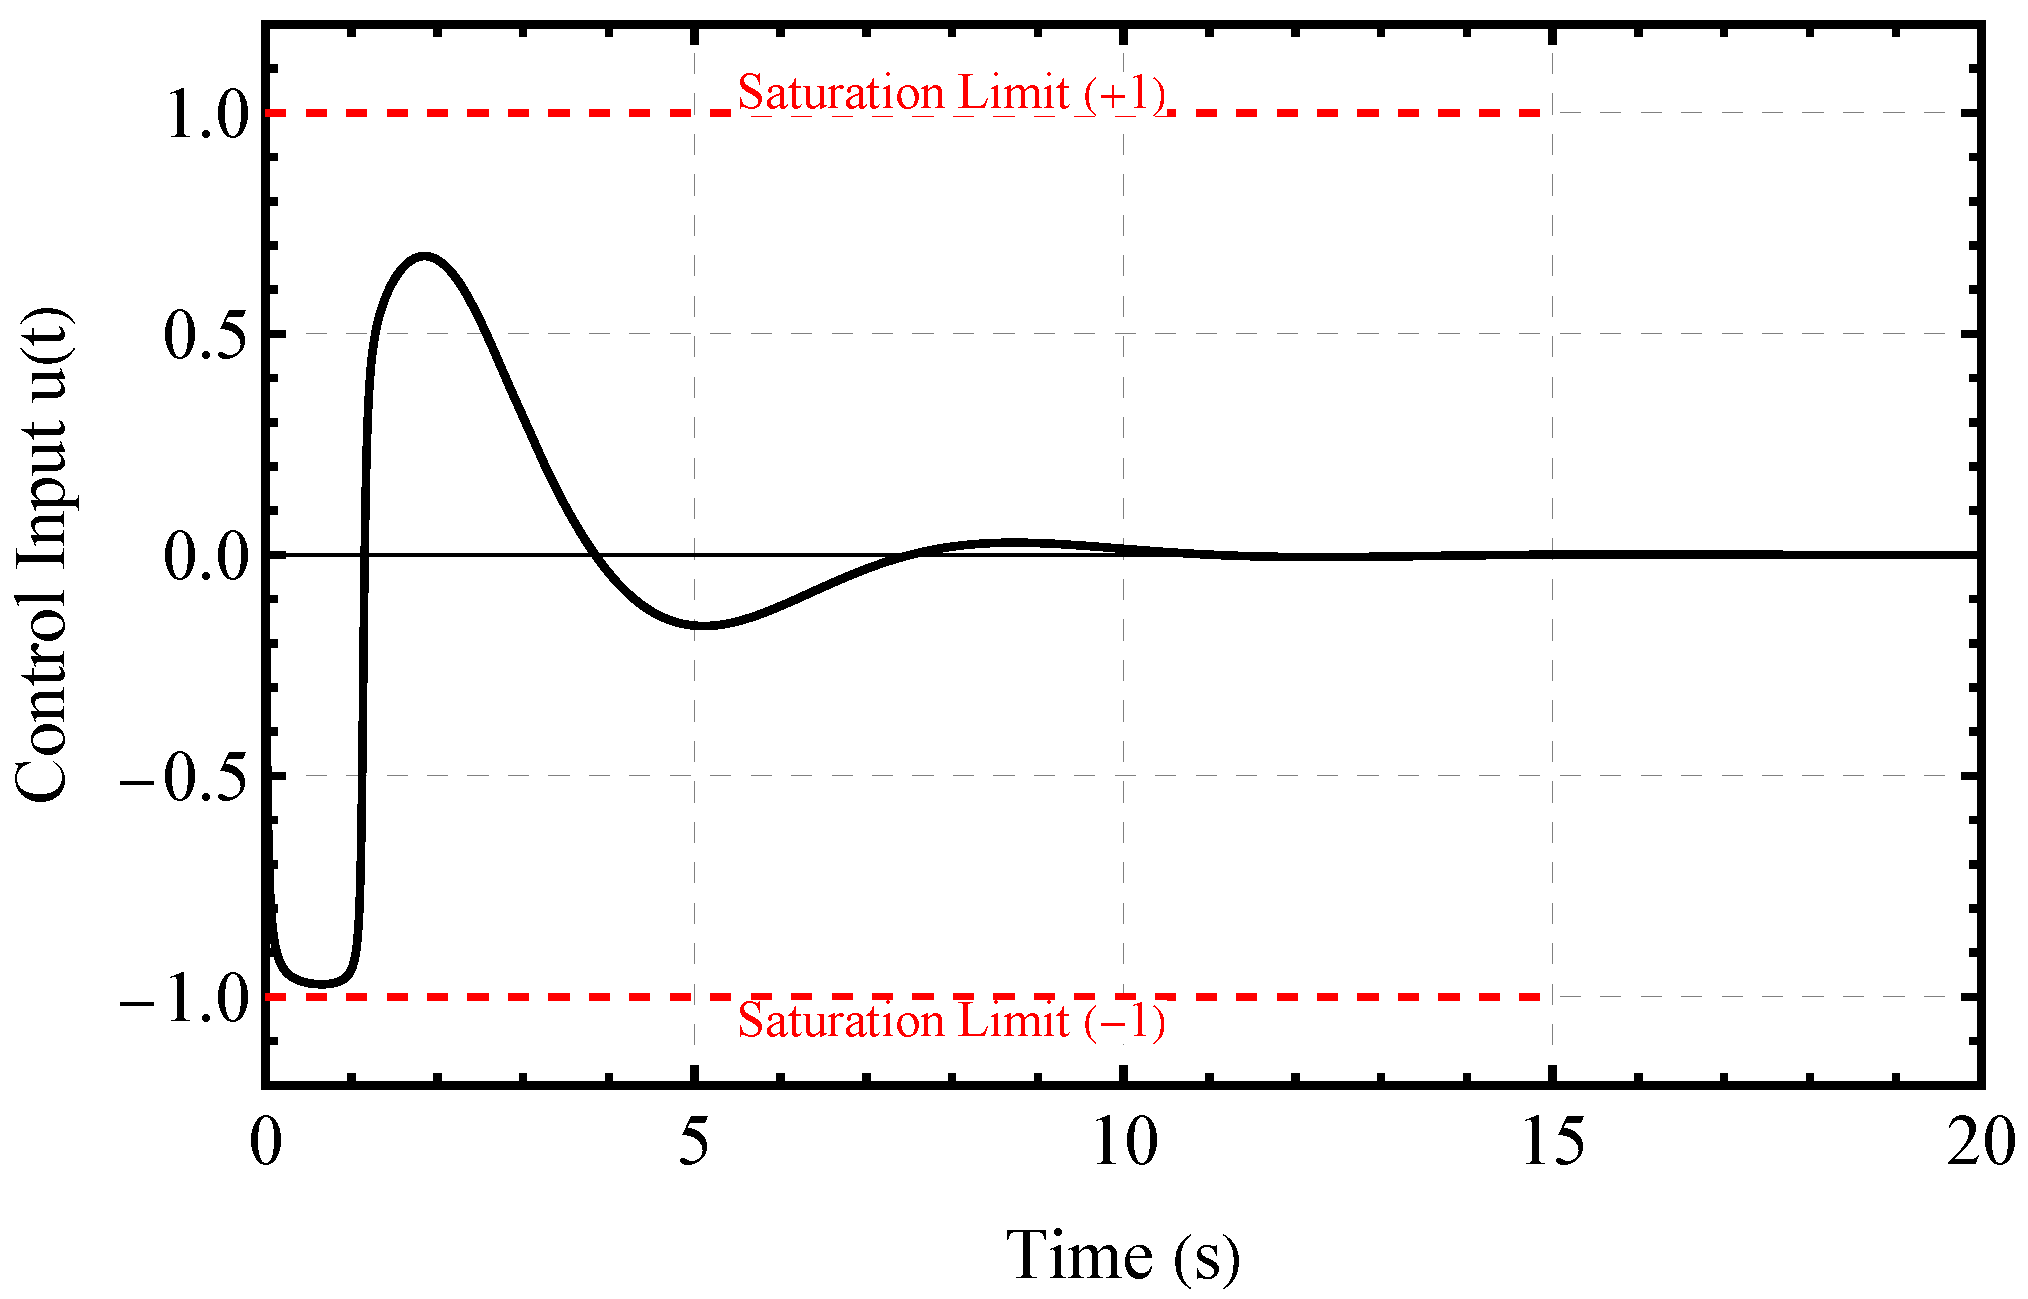
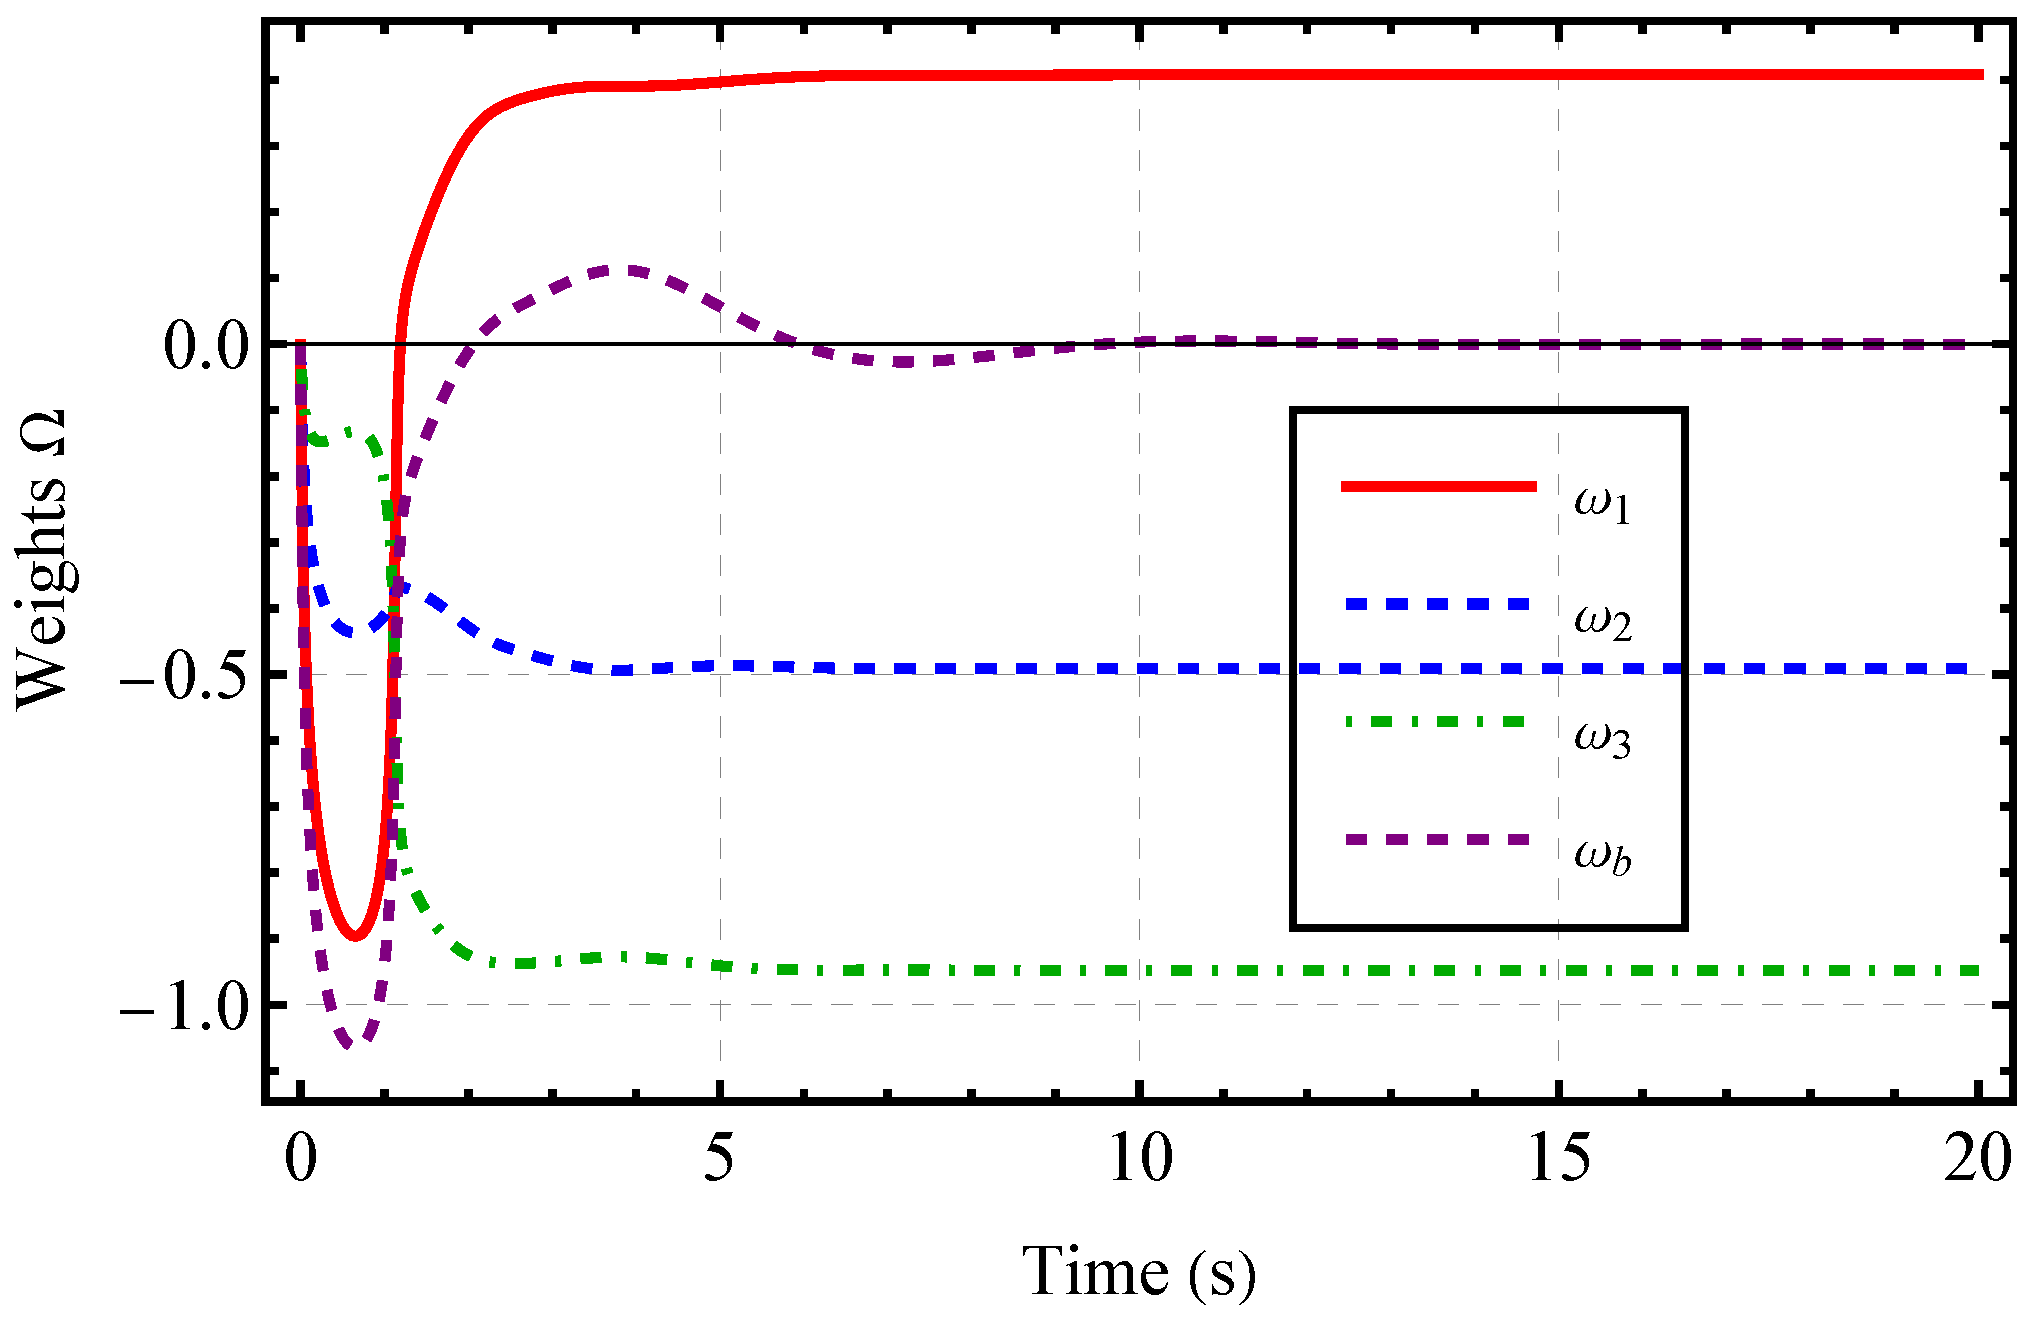
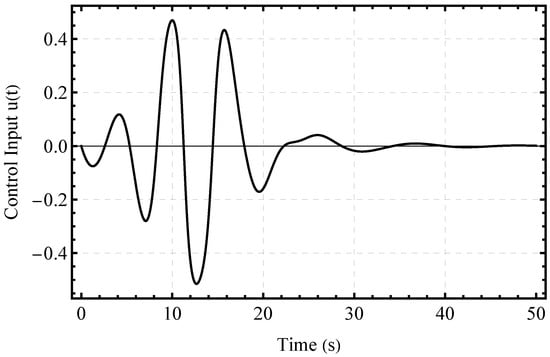
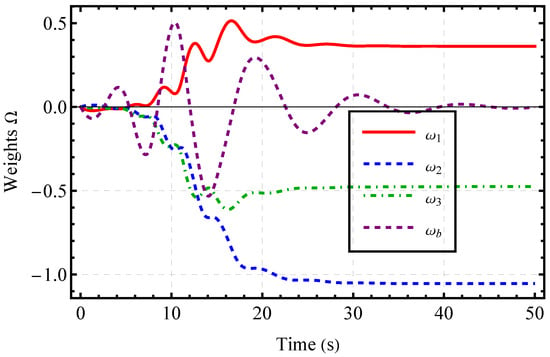
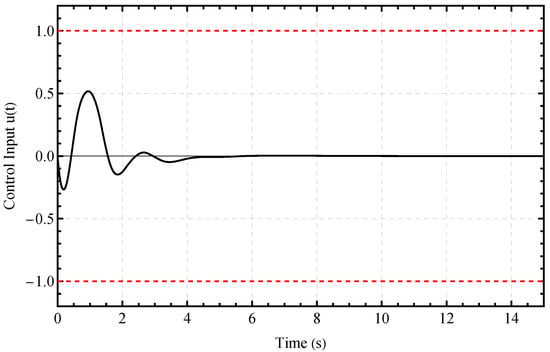
Simulation results are summarized in Figure 1, Figure 2, Figure 3 and Figure 4. Figure 1 depicts the time evolution of the state trajectories starting from the initial condition , and , which lies within the established region of attraction. States exhibit smooth asymptotic convergence to the origin. The transient response of sliding surface s is illustrated in Figure 2. This plot focuses on first 2 s to highlight the fast time-scale dynamics, demonstrating how the adaptive controller rapidly forces s into boundary layer . Figure 3 presents the adaptive controller signal u. It is evident that control effort remains bounded within , thereby avoiding saturation limits and corroborating that system operates within the validity region (27). Finally, Figure 4 shows the dynamics of weights and control bias, it is evident that weights () converges to a constant value for chain of integrators system stability meanwhile bias () converge to zero.
Figure 1.
Time evolution of the system states (, , ).
Figure 2.
Transient response of the sliding surface s.
Figure 3.
Control input signal .
Figure 4.
Weights .
3.2. Example 2: Outside the Region of Attraction
To show limitations of the proposed adaptive control law, a second scenario is analyzed where initial conditions are selected outside of established region of attraction (27). Parameters () and learning rate () remain identical to the previous case.
The initial states are chosen as:
Evaluating equivalent control condition for these values:
The summary of the simulation conditions can be found in Table 2.
Table 2.
Simulation parameters for Example 2 (Outside the Region of Attraction).
Since the required initial control effort () exceeds the saturation limit (), so the condition for existence of the sliding surface is violated at . Consequently, learning in adaptive law (3) is saturated immediately, leading to a temporary loss of control authority and a deviation from ideal slow manifold dynamics.
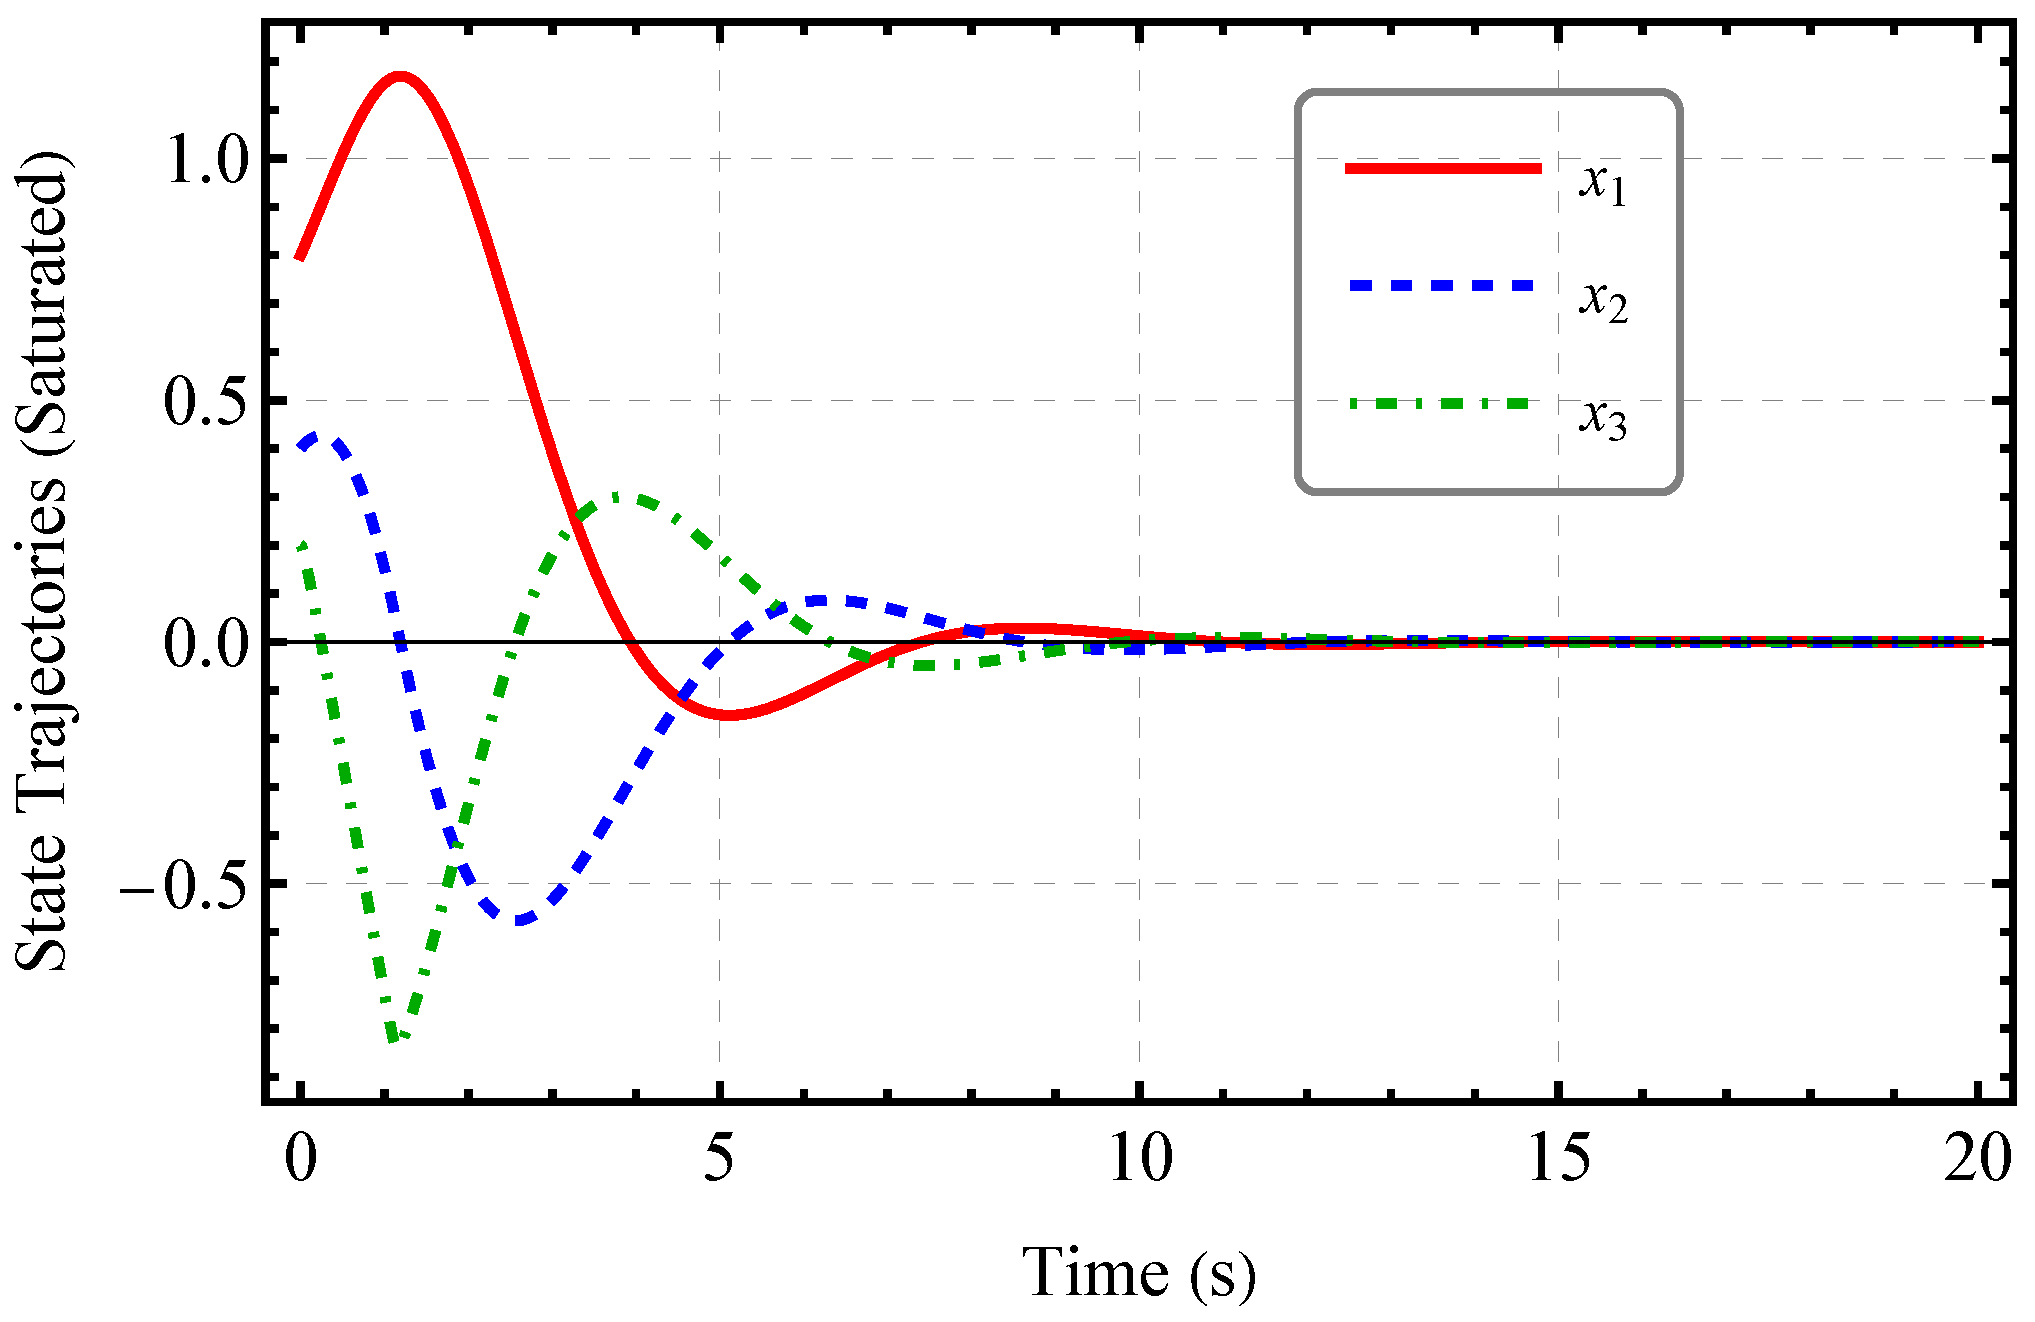
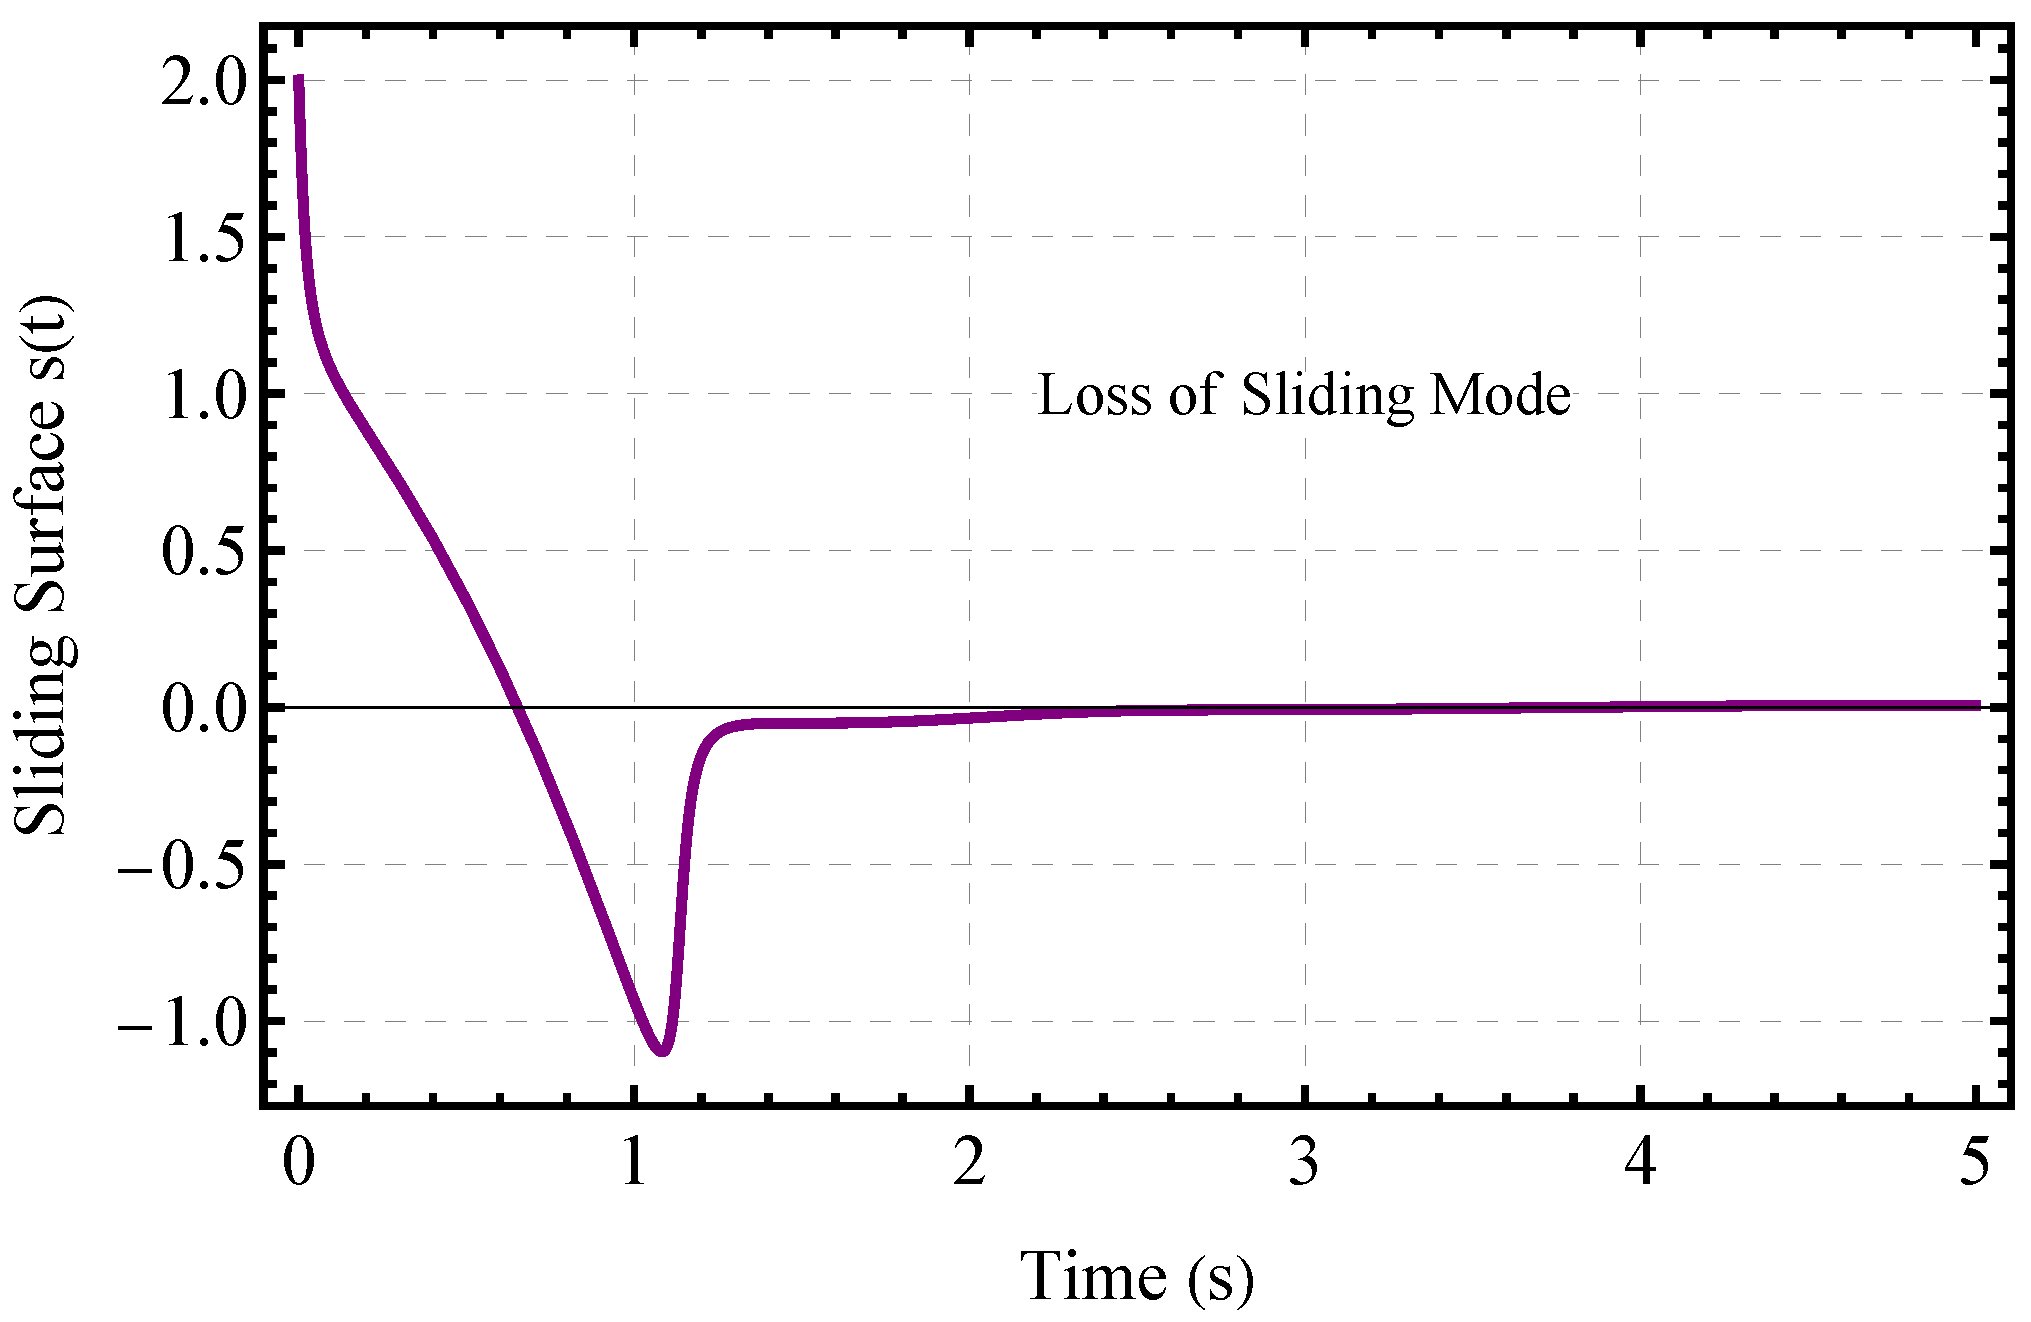
The simulation results for this rigorous test case are presented in Figure 5, Figure 6, Figure 7 and Figure 8. Figure 5 illustrates state trajectories starting from the initial condition , and , which lies outside the established region of attraction. In this case, convergence to the origin is slower than the previous case and exhibits a distinct transient behavior due to control saturation shown in Figure 7. Figure 6 illustrates sliding surface behavior. In this case, the sliding surface s converges to zero more slowly than the previous case. Instead, s deviates significantly during the initial phase, which indicates that the trajectories of the system have departed from slow manifold. The cause of this behavior can be seen in Figure 7, which shows the control signal which is significantly close to saturation limit during the initial period. When the states of the system decay close enough to re-enter in region of attraction the control signal is no longer saturated, allowing the adaptive law recover the sliding motion and eventually stabilize the states of the system. Figure 8 shows that weights and bias increase during the saturation period in order to return the system to the region of attraction and subsequently converges to a constant value.
Figure 5.
State trajectories () under saturation conditions.
Figure 6.
Sliding surface s showing loss of sliding mode.
Figure 7.
Saturated control input .
Figure 8.
Weights in saturated case.
3.3. Example 3: Insufficient Time-Scale Separation
The proposed controller is theoretically based on Tikhonov’s Theorem, which assumes separation between fast dynamics (8c) and the slow dynamics (8a) and (8b). This separation is governed by the singular perturbation parameter . To show the necessity of a high learning rate, a third scenario is simulated where is significantly reduced. The parameters of the system and initial conditions are identical to the Ideal Case (Example 1).
The learning rate is set to:
The summary of the simulation conditions can be found in Table 3.
Table 3.
Simulation parameters for Example 3 (Insufficient Time-Scale Separation).
With , fast subsystem (8c) is no longer sufficiently faster than the slow subsystem (8a) and (8b). Then, assumption that the sliding surface s reaches to boundary layer instantaneously relative to state dynamics is no longer valid.
Figure 9, Figure 10, Figure 11 and Figure 12 summarize the results of this case. Figure 9 shows state trajectories . Unlike the monotonic convergence observed in Example 1, states exhibit significant oscillations and overshoot. This performance degradation confirms that without a sufficiently high learning rate, adaptive law can not track the system dynamics effectively. This is clear in Figure 10, where sliding surface s does not converge fast enough to zero. Instead, it fluctuates significantly, because system is not operating on the desired slow manifold. Finally, Figure 11 displays control signal . The control adaptation is sluggish, failing to generate high-frequency adjustments required to maintain the sliding condition. Due to the low learning rate , the adaptation weights and biases exhibits a slow response in achieving system stability, as illustrated in Figure 12. This example empirically validates the theoretical requirement for a high gain to ensure asymptotic stability. It is evident that weights and bias has oscillatory behavior before converges to a constant values.
Figure 9.
Oscillatory state trajectories due to low learning rate ().
Figure 10.
Sliding surface s failing to converge rapidly.
Figure 11.
Sluggish control input response.
Figure 12.
Weights in low case.
Table 4 provides a comprehensive summary of the behavior of the system behavior across the three simulated scenarios.
Table 4.
Performance and parameter comparison among Examples 1, 2, and 3.
3.4. Comparative Simulation
To illustrate the practical applicability of the proposed controller beyond pure chain integrator systems, an inverted pendulum on a cart (IPC) benchmark is considered in this section. IPC system is an underactuated system that can be transformed into a chain of integrator system plus a nonlinear perturbation as shown in [9,42].
In order to evaluate the performance and robustness of the proposed ANC, this section presents a comparative numerical analysis against three control strategies: the LQR controller, the Nested Saturation Control scheme proposed in [9], and a Sliding Mode Controller (SMC). The objective is to demonstrate the ability of the ANC to achieve asymptotic stability in the IPC system while handling nonlinearities and bounded control constraints. All four controllers were simulated under identical initial conditions (, , , ) and performance was compared using the Integral of Time-weighted Squared Error (ITSE) index applied to the control input. The parameter tuning procedure for each controller is described below.
ANC parameters. The IPC system is a fourth-order underactuated system; consequently, the proposed ANC incorporates four design parameters . These gains are selected such that the associated characteristic polynomial satisfies the Routh-Hurwitz stability criterion. The selected values are , , , and . The learning rate is set to , ensuring a sufficiently small singular perturbation parameter . All neural network weights are initialized to zero, i.e., .
LQR parameters. The LQR controller was synthesized by defining the state weighting matrix as and the control weighting scalar as . The optimal gain vector was computed by solving the algebraic Riccati equation using the lqr() function in MATLAB R2025b, yielding the state feedback gain , so that . The control output was saturated to to match the bounded control constraint shared by the other three controllers.
Nested Saturation parameters. The Nested Saturation controller follows the design of Ibañez and Frías [9]. The control structure employs four auxiliary coordinates defined as , , , and . The nested saturation levels are set to , , and , with the global saturation gain . The resulting control law is:
where denotes the standard saturation function with level L.
SMC parameters. The SMC is designed using the sliding surface
with coefficients , , , chosen to place the sliding surface dynamics at stable eigenvalues. The control law is composed of an equivalent control term and a switching term :
where is the nonlinear drift term of the IPC dynamics, is the switching gain, and is the boundary layer thickness. The hyperbolic tangent replaces the discontinuous sign function to eliminate chattering while preserving bounded control action.
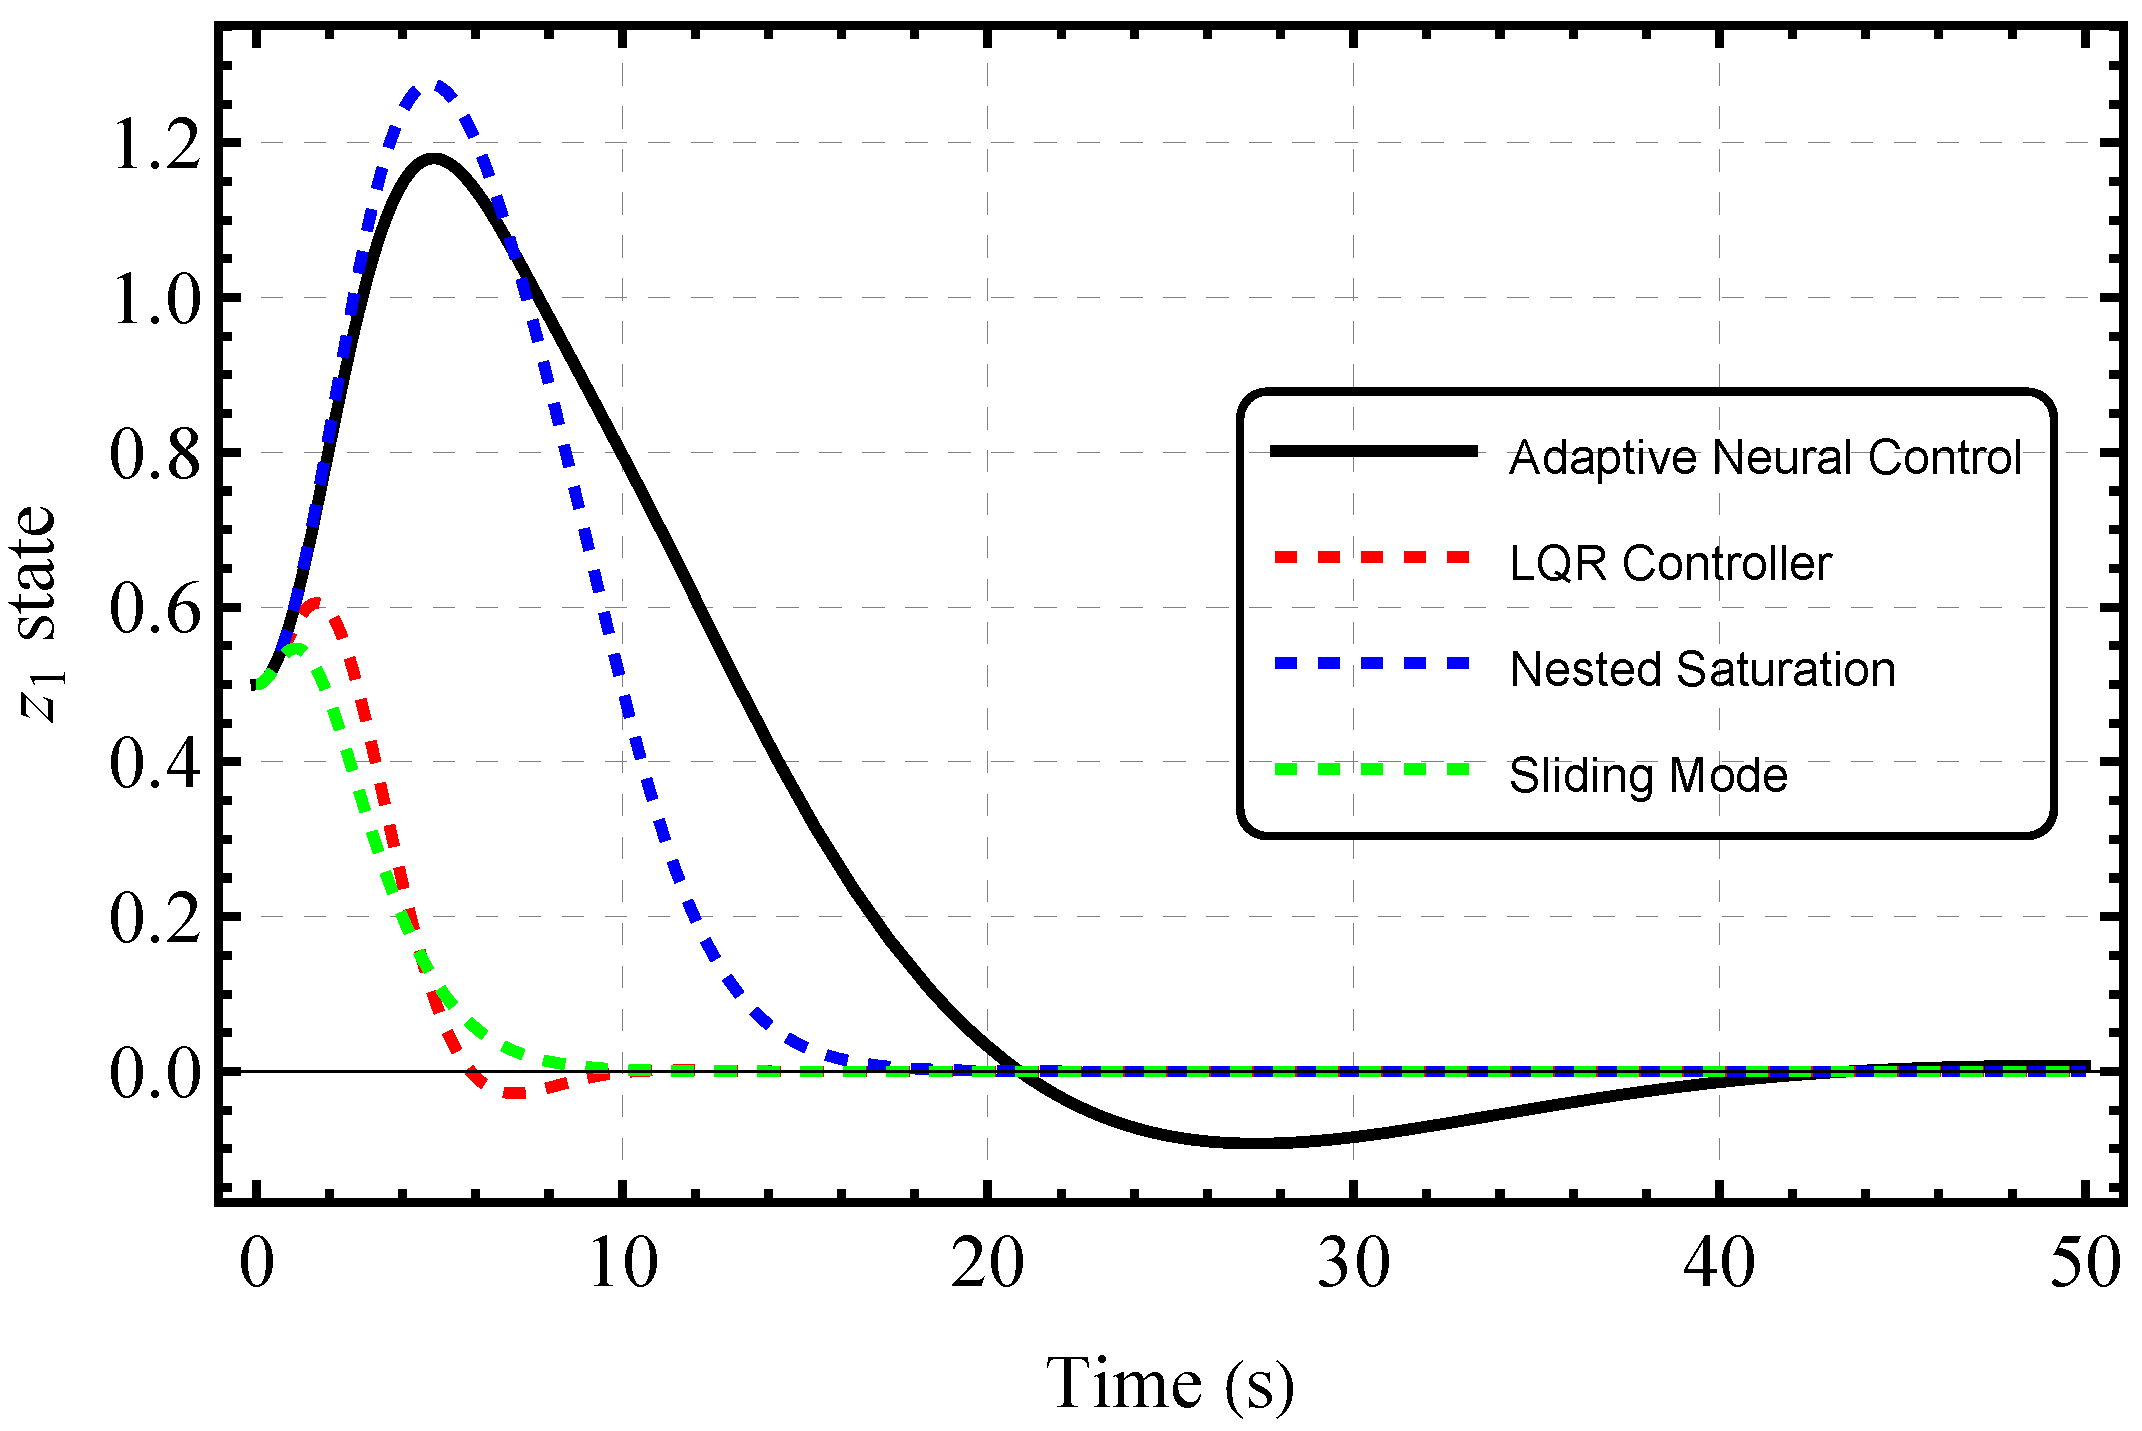
The dynamic behavior of state under the four control strategies is shown in Figure 13. It is observed that SMC controller achieves the fastest stabilization, exhibiting shorter settling time and a reduced overshoot compared to the others alternatives. On the other hand, ANC demonstrates a slower convergence rate than rest of controllers; however, it minimizes the overshoot, outperforming Nested Saturation scheme in terms of transient smoothness.
Figure 13.
Comparative behavior of state .
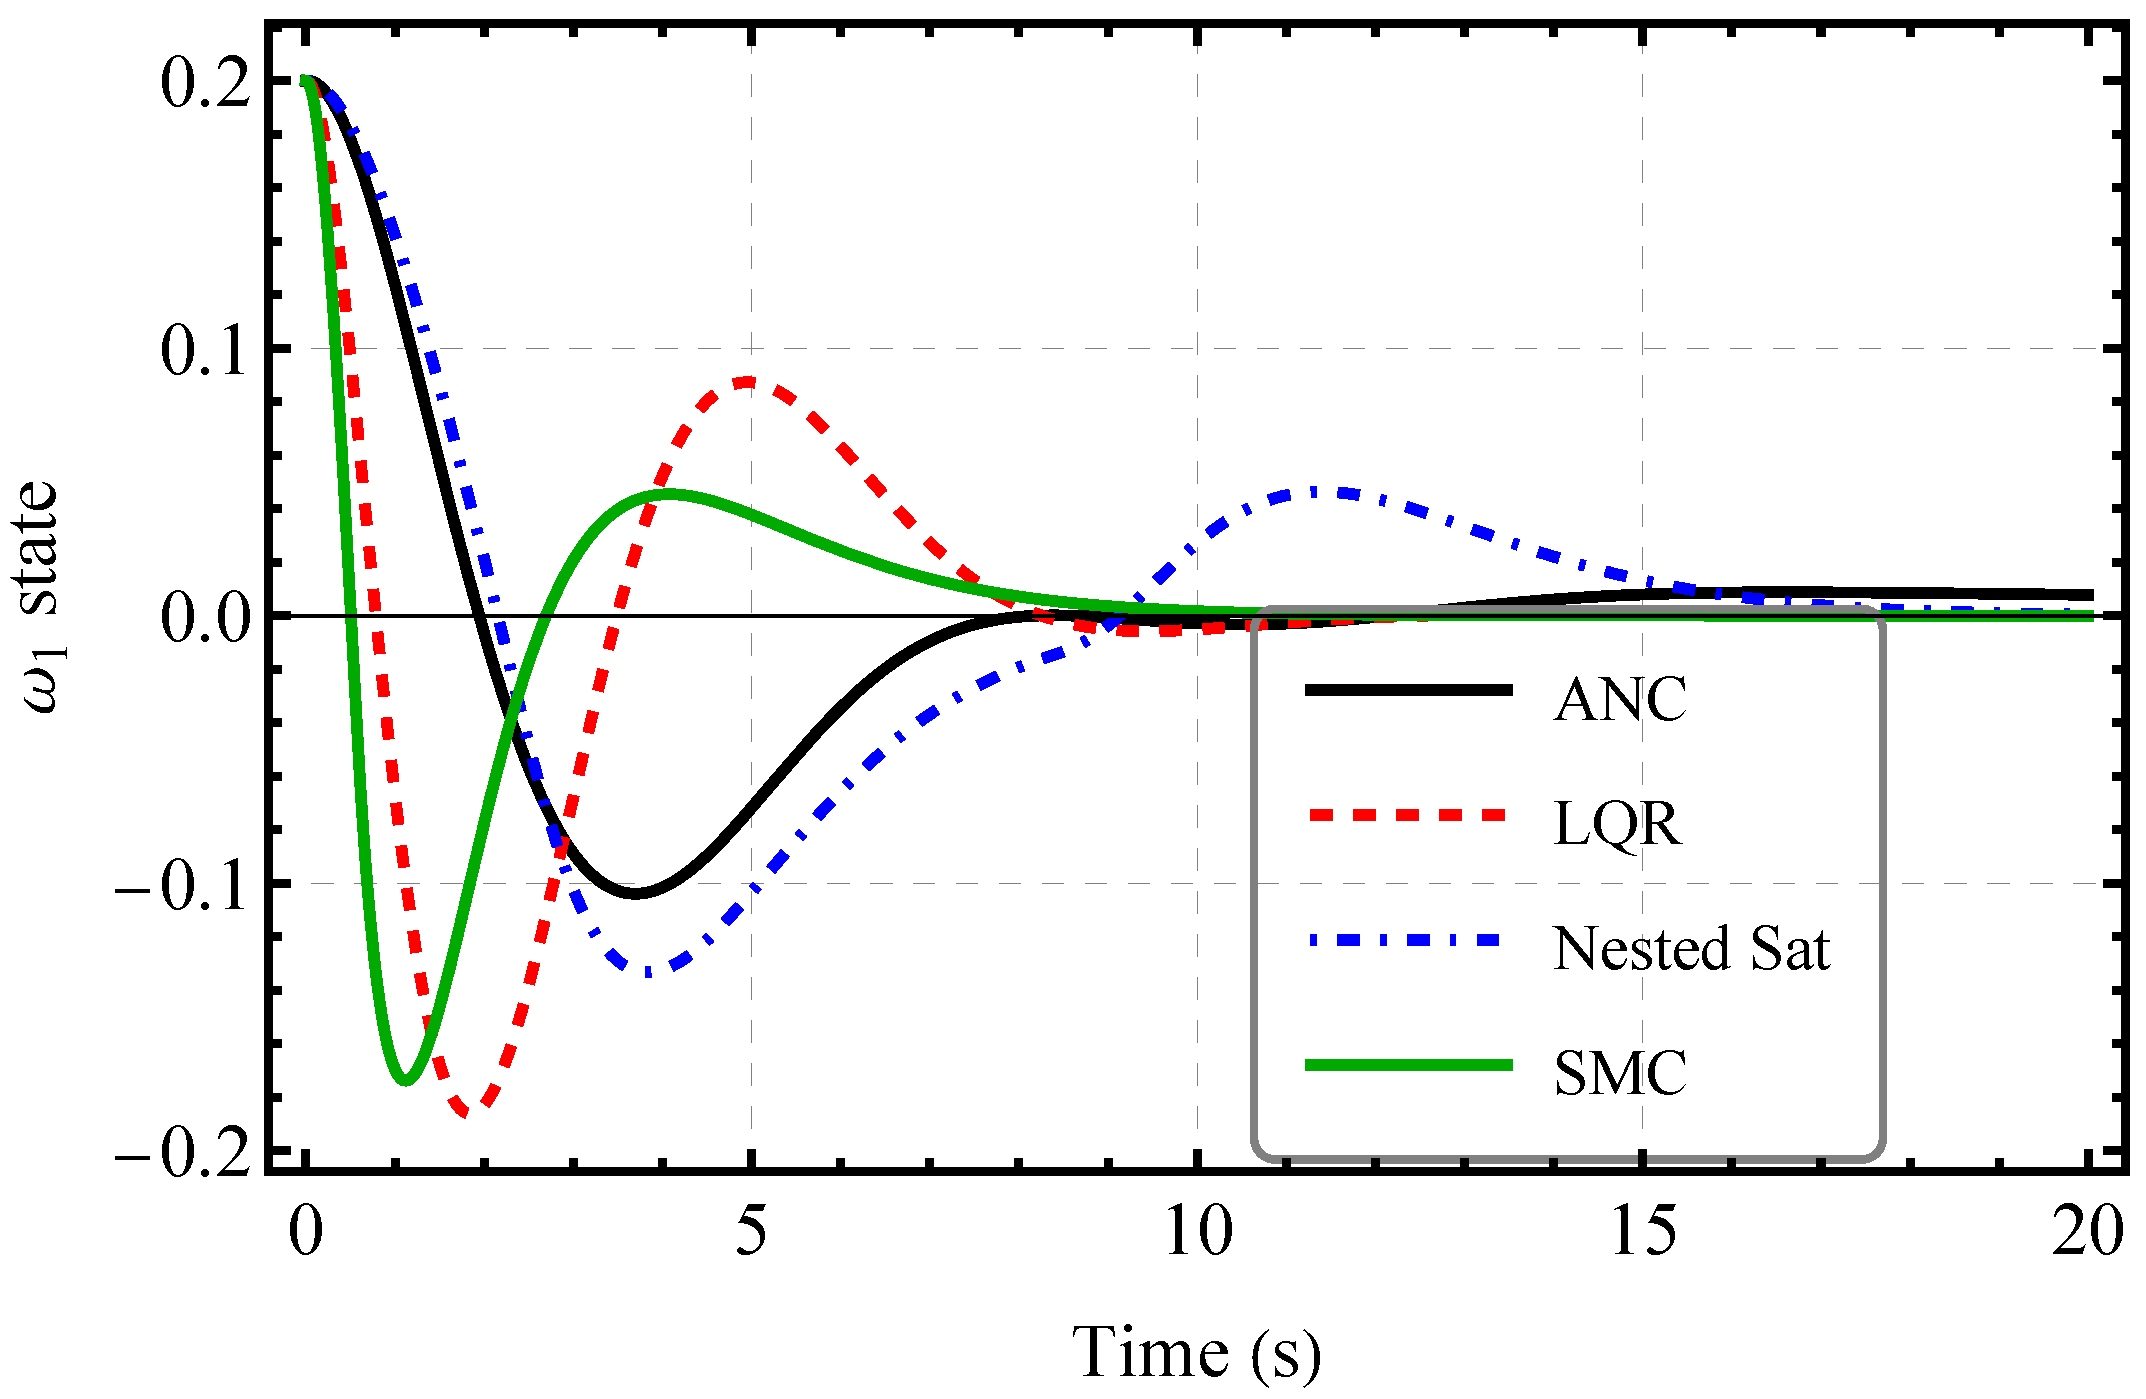
Similarly, Figure 14 illustrates the dynamic response of angular state under the four aforementioned control strategies. It is observed that four controllers exhibit comparable peak overshoots and similar settling times. However, the proposed ANC demonstrates better performance in terms of oscillation damping, maintaining a lower amplitude during transient phase compared to the other control schemes.
Figure 14.
Comparative behavior of state .
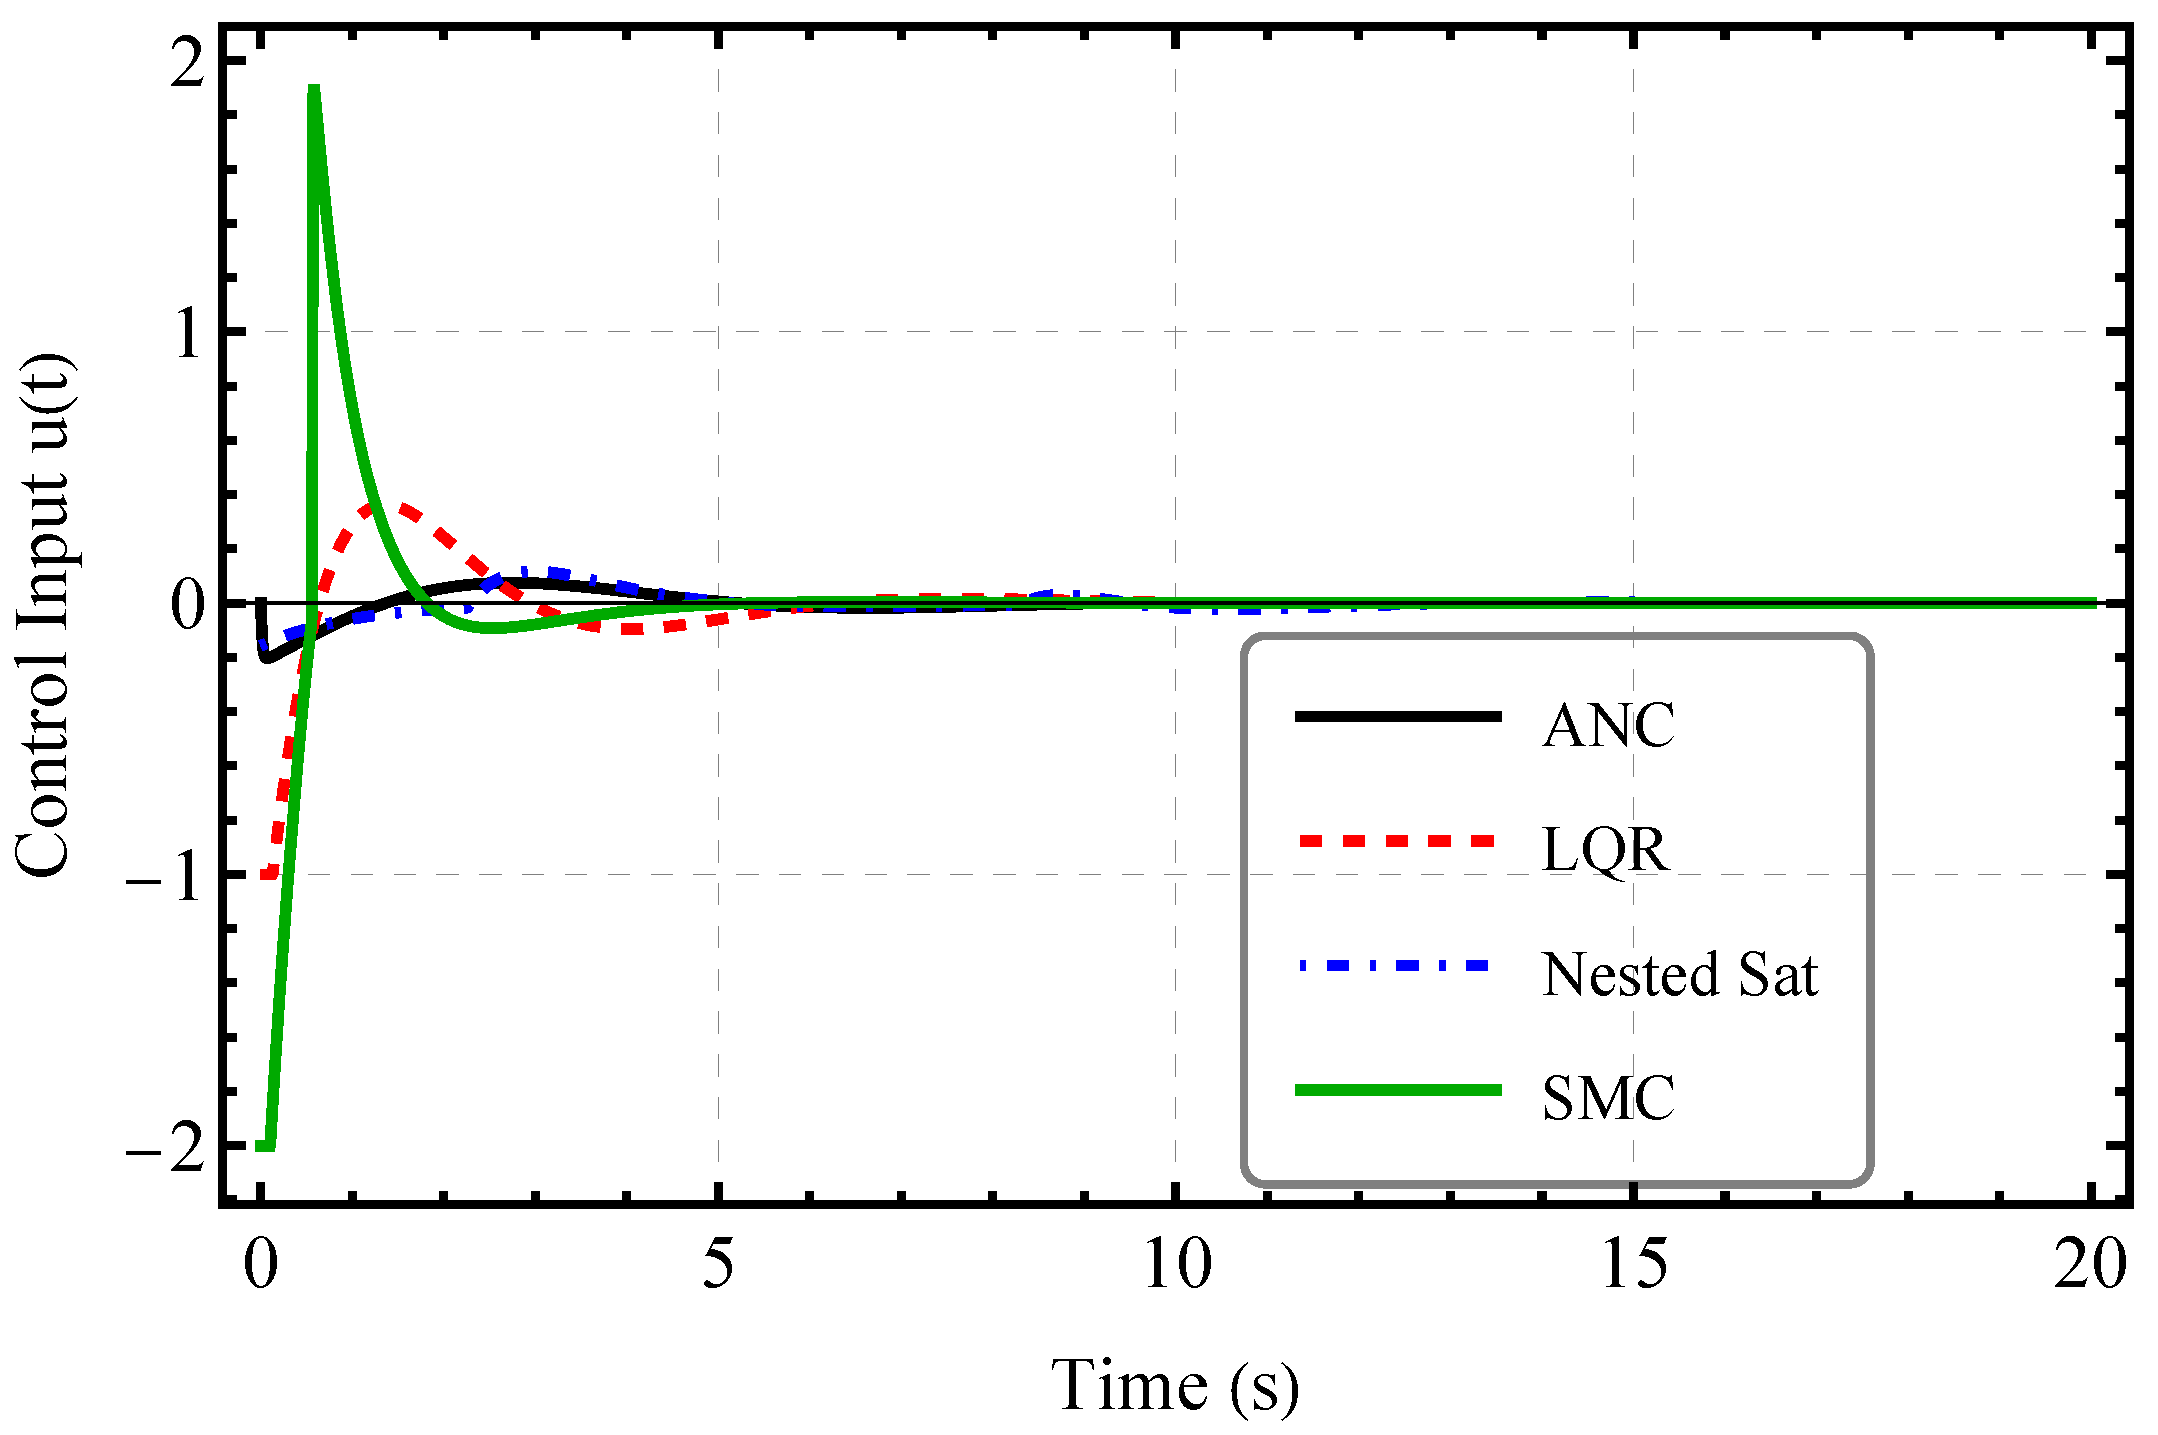
Figure 15 illustrates the dynamic behavior of the control input for each of the evaluated strategies. It can be observed that the proposed ANC exhibits a significantly lower overshoot compared to the alternative controllers. This smoother transient response indicates a substantial reduction in the required control effort, thereby implying greater energy efficiency.
Figure 15.
Comparative behavior of Controllers.
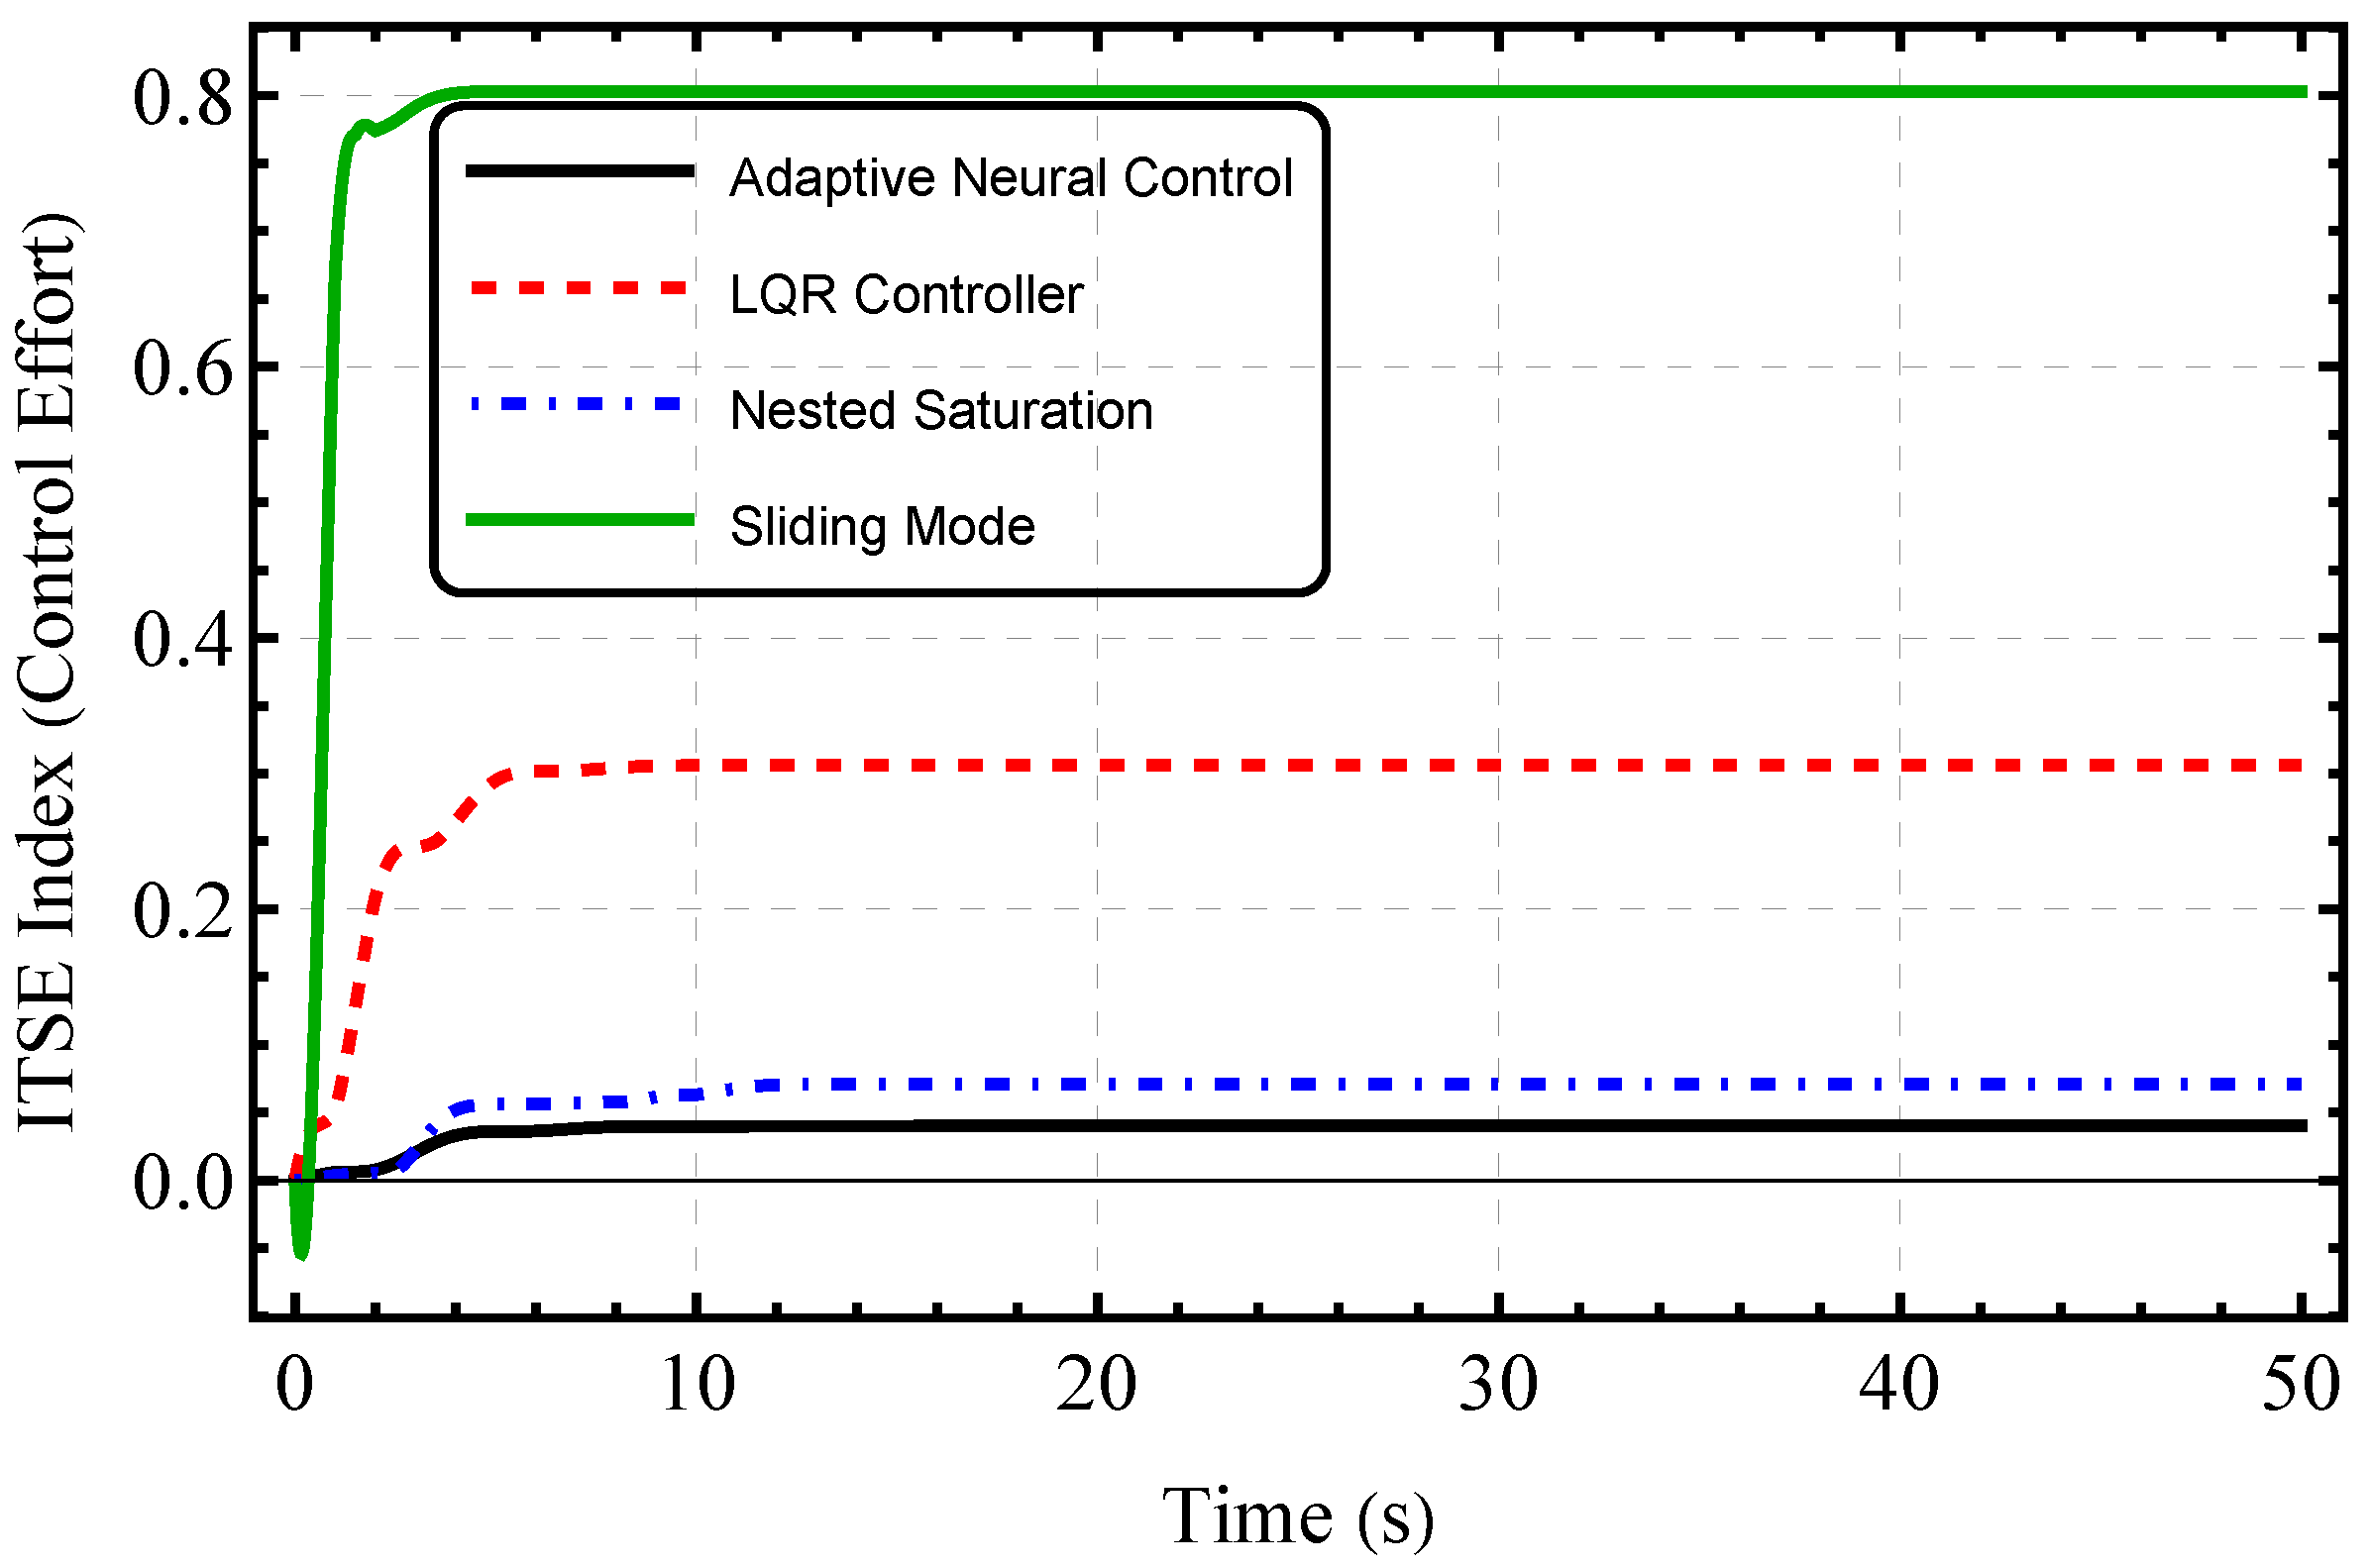
To evaluate the performance of ANC, LQR, Nested Saturation scheme and SMC, Integral of Time-weighted Squared Error (ITSE) criterion was applied to the control input. This metric was selected to quantify the control effort associated with each strategy, providing a clear indication of how each controller manages the trade-off between transient speed and power consumption. Results of ITSE criterion are shown in Table 5 and Figure 16.
Table 5.
Performance Analysis based on ITSE Index.
Figure 16.
Comparative ITSE criterion.
In quantitative terms, the proposed ANC demonstrates a performance improvement of over LQR controller, compared to nested saturation functions and against SMC scheme, based on evaluation of ITSE performance index. As shown in Figure 13, Figure 14 and Figure 15, the settling time achieved with ANC is longer than those of the other control schemes.
It is important to remark that the proposed ANC does not incorporate an explicit compensation term for the nonlinear term of the IPC system, unlike the SMC which actively cancels this nonlinearity. The ANC treats this term as an unmodeled bounded perturbation. Consequently, the ANC exhibits a slower transient response and longer settling time. The significant reduction in the ITSE index should be interpreted as a measure of control effort efficiency and transient smoothness rather than a proof of absolute theoretical robustness against nonlinear uncertainties. The ability of the ANC to stabilize the perturbed system without an explicit robustifying term highlights its local tolerance to unmodeled dynamics within the region of attraction, trading off convergence speed for bounded, low-energy control action.
3.5. High-Order System Simulation
Furthermore, numerical simulations were conducted on a fifth-order system in order to stabilize the system using the proposed ANC scheme. The parameters are selected to satisfy the Routh-Hurwitz stability criterion for reduced-order polynomial . The parameters are chosen as:
which ensures that slow dynamics are asymptotically stable.
Learning rate for adaptation law is set to , ensuring a sufficiently small singular perturbation parameter . The initial weights of the neural network are set to .
To validate the controller within the region of attraction , the initial states are chosen as:
Substituting these values into the condition for defined in (27):
The summary of the simulation conditions can be found in Table 6.
Table 6.
Simulation parameters for the High-Order System Simulation.
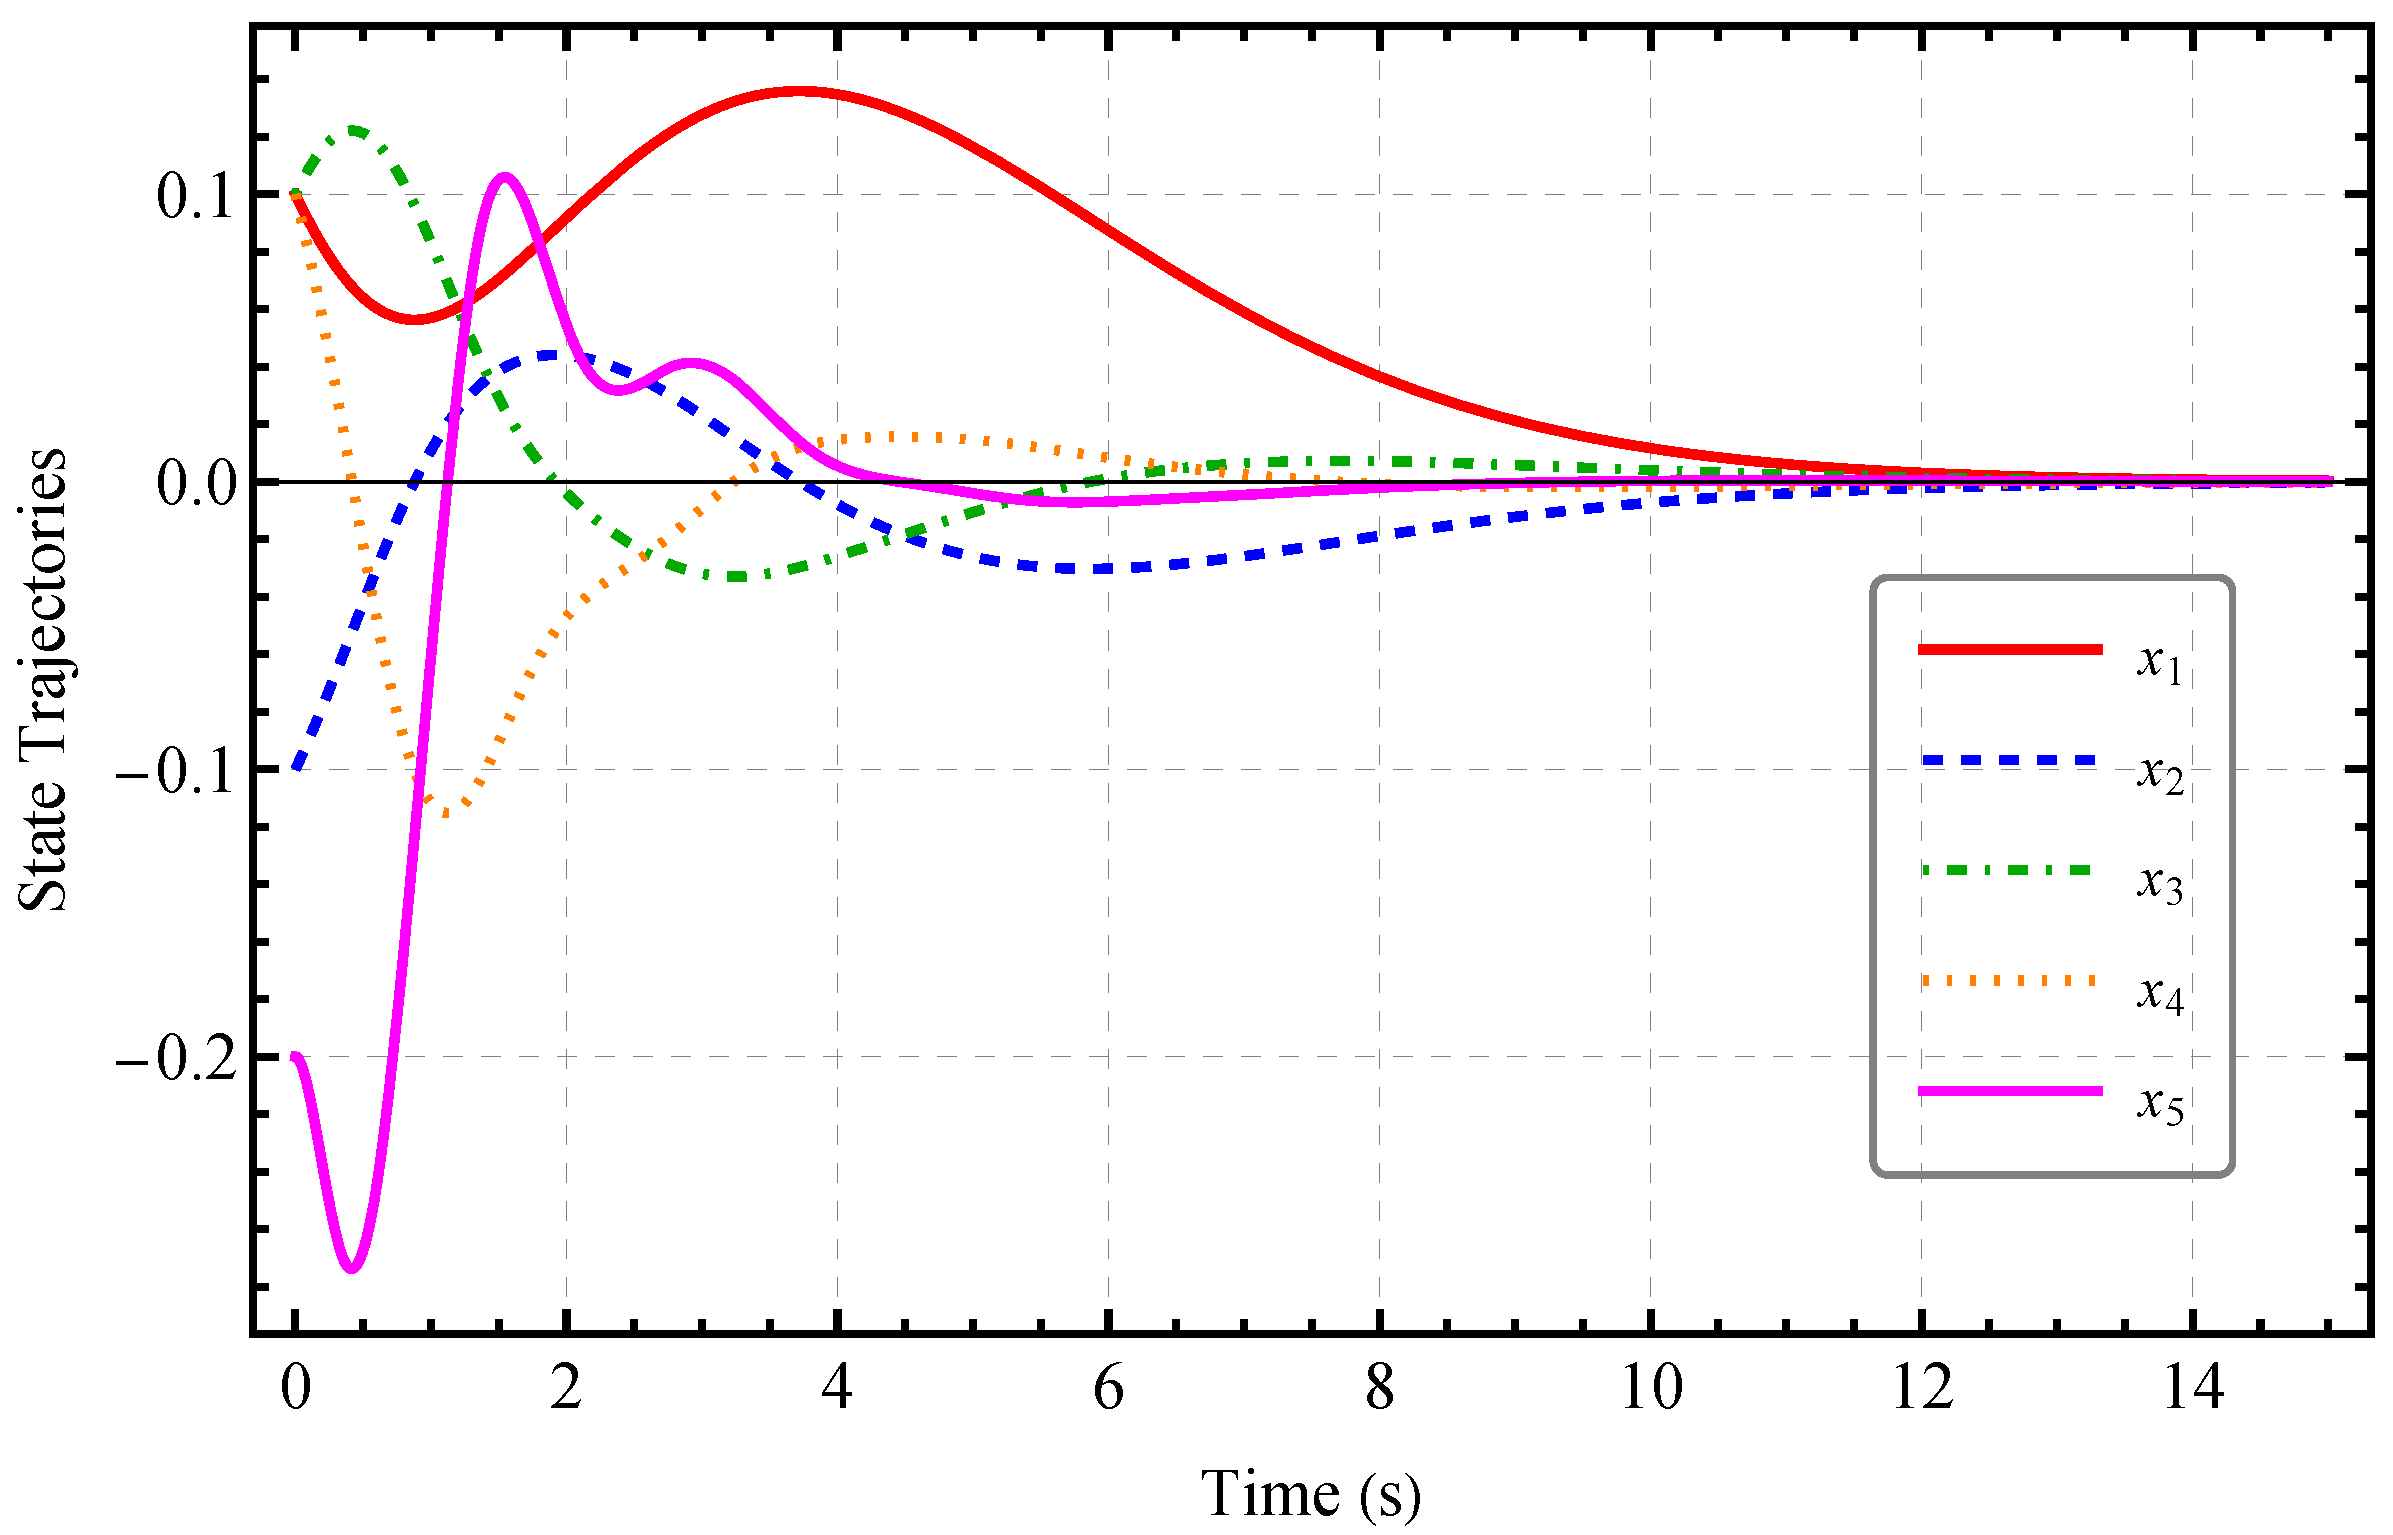
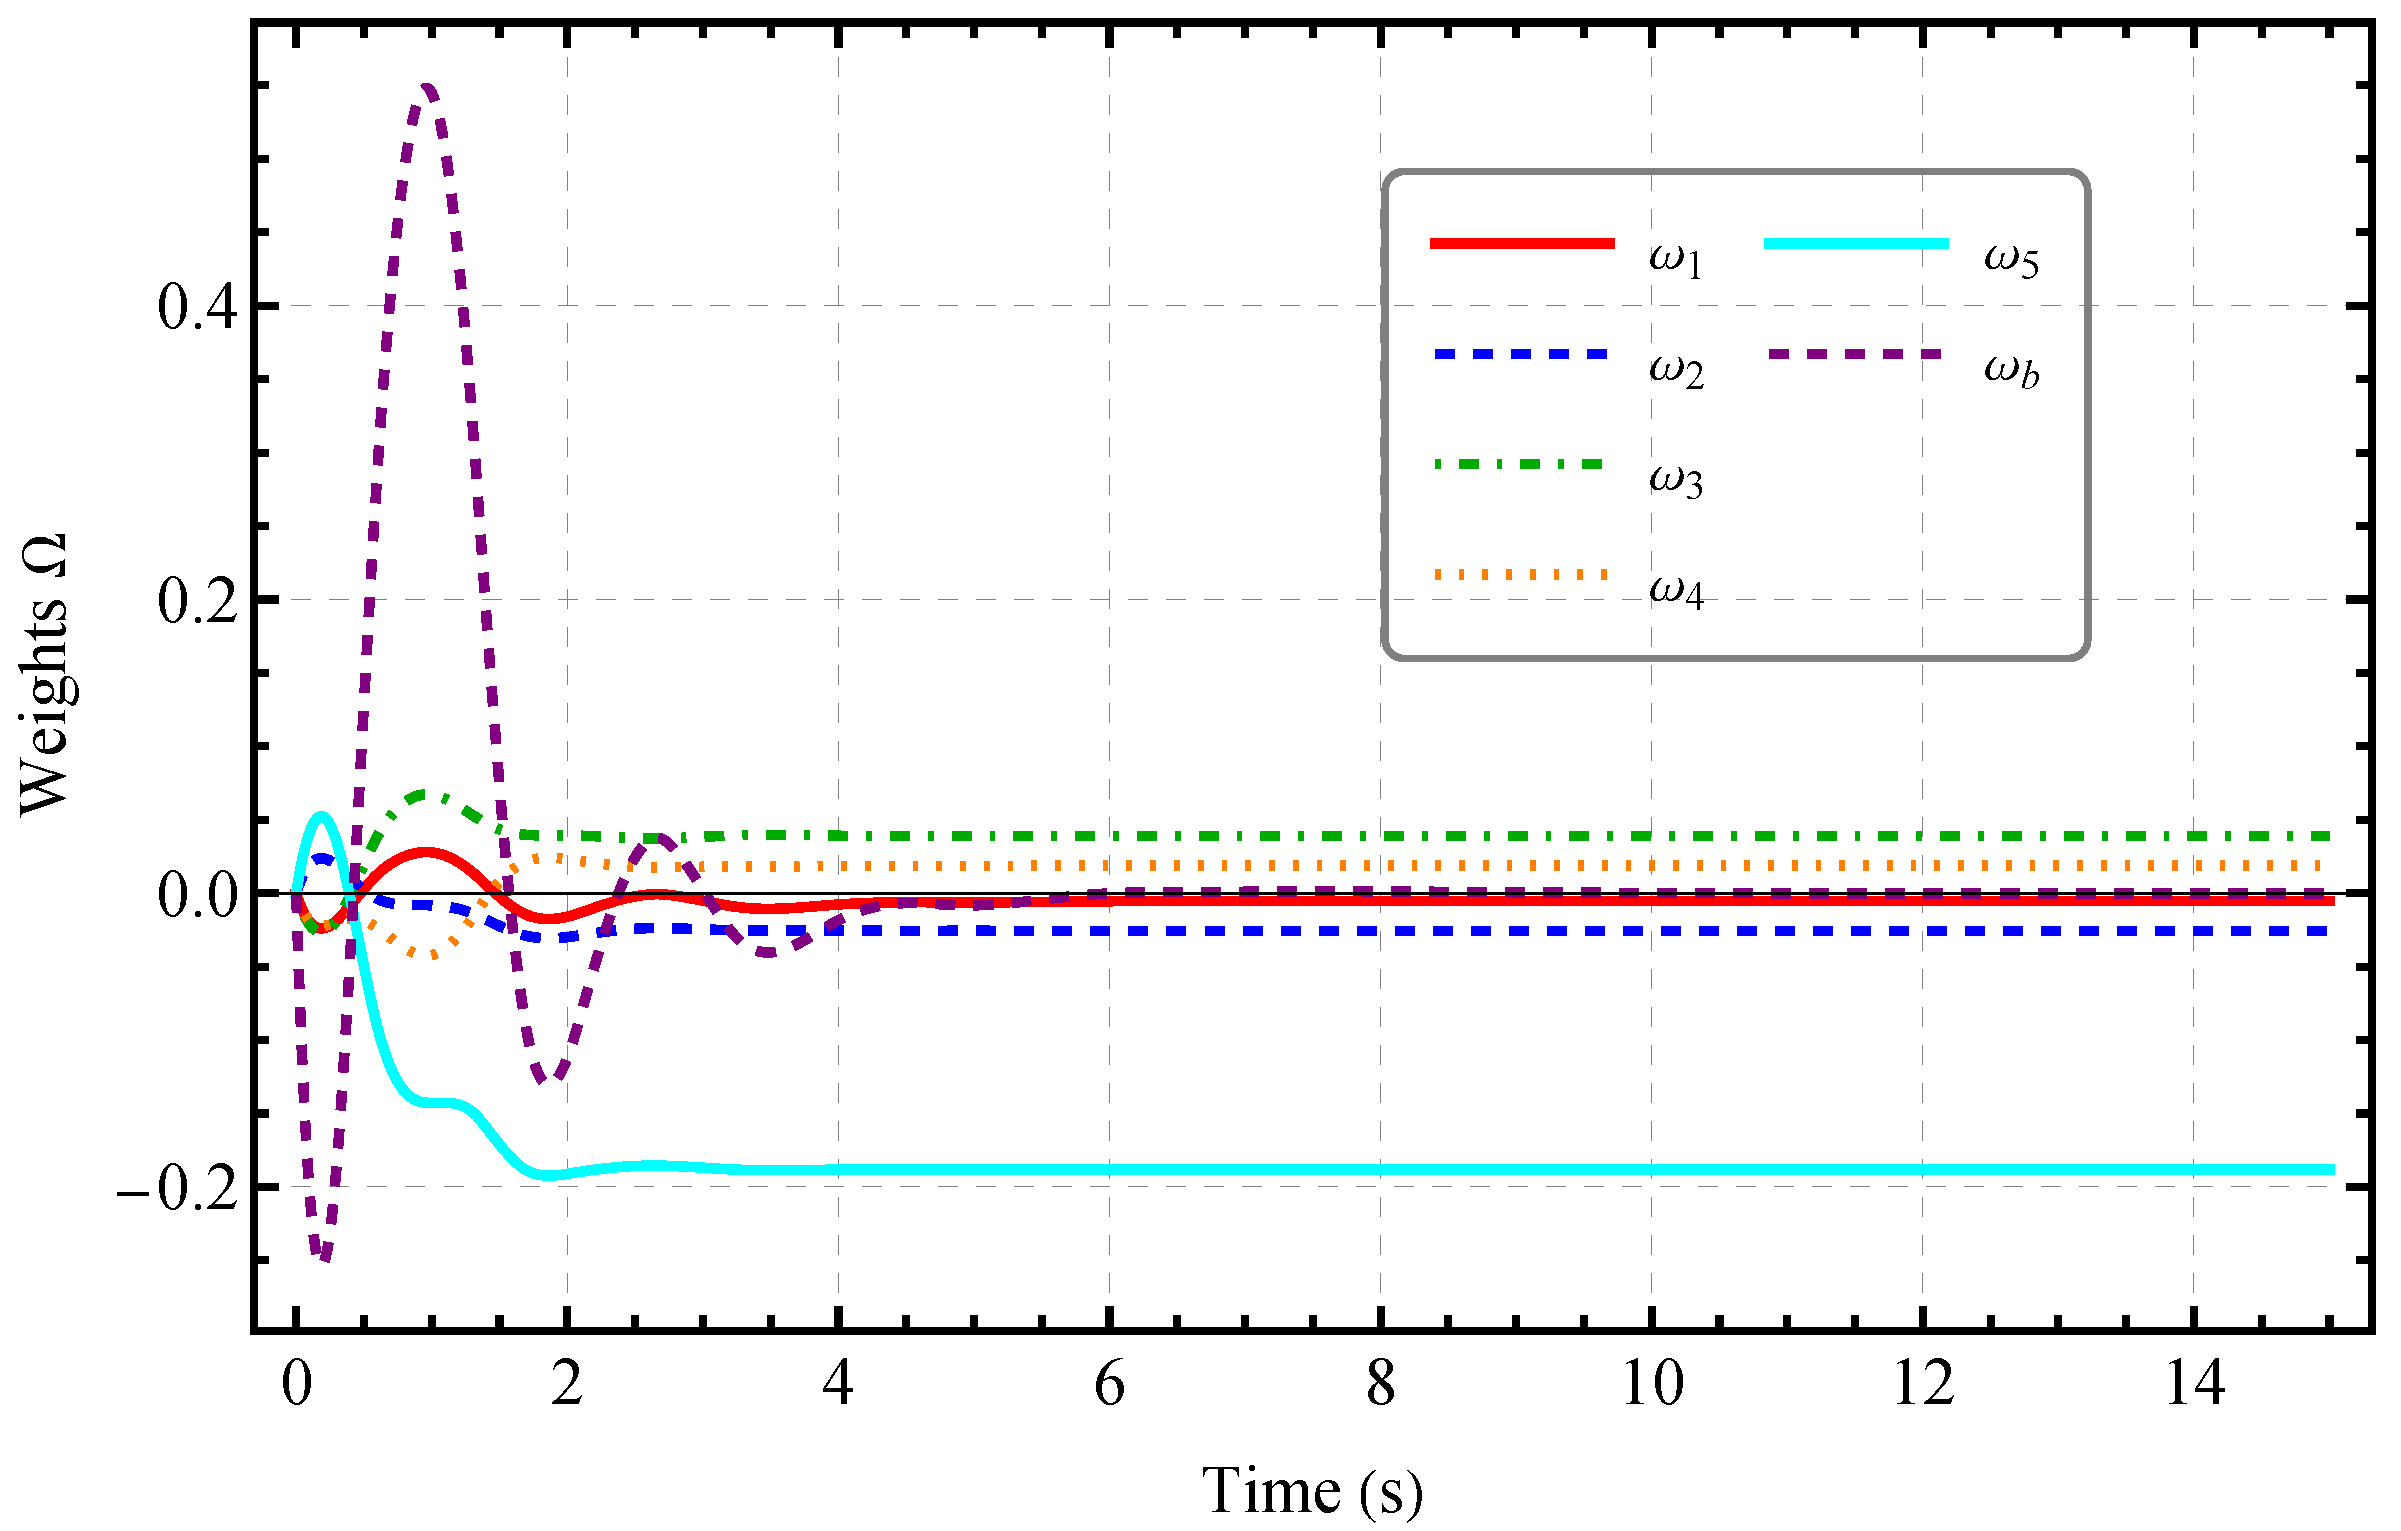
Figure 17 illustrates the time response of the fifth-order system under the proposed ANC. It can be observed that all system states asymptotically converge to zero, demonstrating the effectiveness of the control law in achieving local asymptotic stabilization for initial conditions within the region of attraction . Figure 18 displays the time evolution of the adaptive weights of the proposed ANC. It can be observed that the parameters undergo a dynamic adjustment phase during the transient period of the system and subsequently reach constant steady-state values. Figure 19 illustrates the performance of the controller for the fifth-order system. This behavior confirms the convergence of the learning dynamics and the stability of the adaptive law.
Figure 17.
Time evolution of the system states (, , ).
Figure 18.
Time evolution of Weights in system of order 5.
Figure 19.
Control input signal in system of order 5.
These results demonstrate that the proposed ANC scheme ensures asymptotic stability, provided that the learning rate is sufficiently high and the initial conditions remain within the region of attraction .
4. Discussion
The proposed ANC differs from classical adaptive neural control architectures commonly found in the literature in two fundamental aspects: structural simplicity and the stability analysis framework. By employing a single-neuron structure with a hyperbolic tangent activation function, the proposed controller significantly reduces the number of adaptive parameters and the computational burden compared to multi-layer or recursive architectures. The adaptation law is derived directly from the backpropagation algorithm, which provides a clear and well-understood update rule without requiring explicit model knowledge or recursive controller construction.
The proposed ANC differs from classical adaptive neural control architectures commonly found in the literature. Traditional neuroadaptive approaches, such as those proposed by Polycarpou [21] and Lewis [22], typically rely on Lyapunov-based adaptive laws combined with robustifying terms to compensate for approximation errors. These designs often involve multi-layer neural networks or radial basis function networks, which increase the number of adaptive parameters and the computational burden.
In contrast, the controller proposed in this work employs a single-neuron structure with a hyperbolic tangent activation function, significantly reducing the complexity of the adaptation law. While this simplification improves implementability and reduces computational cost, it also limits the approximation capability of the neural structure compared with multi-layer networks used in classical adaptive neural control.
Similarly, sliding mode control techniques provide strong robustness guarantees in the presence of bounded disturbances and modeling uncertainties. However, these methods typically require discontinuous control actions, which may lead to chattering phenomena. Although smooth approximations can mitigate this effect, they often degrade the robustness properties of the controller. The proposed ANC provides a smooth bounded control signal by design, but does not explicitly guarantee robustness against disturbances in the same manner as sliding mode approaches.
Backstepping-based neural controllers provide systematic stability guarantees for strict-feedback nonlinear systems. Nevertheless, their recursive structure introduces the well-known explosion-of-terms problem, leading to complex controller expressions and multiple adaptation loops. The proposed controller avoids this issue by employing a single adaptation law.
Despite the promising results, several limitations of the proposed approach should be highlighted.
First, the stability guarantees derived using singular perturbation theory require a sufficiently high learning rate to ensure time-scale separation between the fast adaptation dynamics and the slow state dynamics. In practical implementations, excessively large learning rates may lead to numerical instability or sensitivity to measurement noise.
Second, the proposed controller ensures asymptotic convergence only within a finite region of attraction, determined by the bounded nature of the tanh activation function. If the required equivalent control exceeds the saturation limits, the sliding condition cannot be maintained, which leads to degraded performance during the transient phase.
Third, the current analysis assumes ideal system dynamics without external disturbances or modeling uncertainties. While the controller demonstrated satisfactory performance in numerical simulations, additional analysis would be required to establish robustness guarantees in the presence of disturbances or parametric uncertainty.
From an implementation perspective, several practical aspects must be considered. The adaptive law requires real-time evaluation of the neural weights and state measurements. In digital control platforms, the continuous-time adaptation law would need to be discretized, which may affect the time-scale separation required by the singular perturbation analysis.
Furthermore, actuator saturation, sensor noise, and limited sampling rates may influence the convergence properties of the adaptive mechanism. In particular, high learning rates may amplify measurement noise, potentially leading to oscillatory behavior in the weight dynamics.
5. Conclusions
This work presented a novel Adaptive Neural Control (ANC) scheme for the asymptotic stabilization of a chain of integrators at the origin. The proposed controller employs a single-neuron structure with a hyperbolic tangent activation function, offering significant structural simplicity by requiring only a single adaptation law derived from the backpropagation algorithm.
Stability analysis conducted via singular perturbation theory demonstrated that a sufficiently high learning rate induces a two-time-scale structure. By applying Tikhonov’s Theorem, it was established that the simultaneous stability of the fast adaptation dynamics and the slow state dynamics guarantees local asymptotic stability of the closed-loop system within a defined region of attraction.
Numerical simulations on third-order and fifth-order chains of integrators validated the theoretical results, demonstrating smooth convergence within the region of attraction and graceful degradation under control saturation. Furthermore, in a comparative study on an Inverted Pendulum on a Cart benchmark, the proposed ANC demonstrated a significant reduction in control effort compared to LQR, Nested Saturation, and SMC strategies, highlighting its superior energy efficiency despite a longer settling time.
Future work will focus on extending the stability framework to explicitly handle bounded external disturbances and parametric uncertainties, as well as investigating hybrid strategies for global stabilization. Additionally, developing systematic tuning procedures for the learning rate, addressing discrete-time implementations, and conducting experimental validation on physical platforms represent promising directions for further research.
Author Contributions
Conceptualization, C.A.V.-R. and O.G.-F.; methodology, C.A.V.-R.; software, C.A.V.-R. and S.C.-L.; validation, C.A.V.-R. and O.G.-F.; formal analysis, C.A.V.-R.; investigation, C.A.V.-R. and S.C.-L.; resources, O.G.-F.; data curation, S.C.-L.; writing—original draft preparation, S.C.-L.; writing—review and editing, C.A.V.-R. and O.G.-F.; visualization, O.G.-F.; supervision, O.G.-F.; project administration, C.A.V.-R. and O.G.-F.; funding acquisition, O.G.-F. All authors have read and agreed to the published version of the manuscript.
Funding
This work was supported by the Secretaría de Investigación y Posgrado del Instituto Politécnico Nacional (SIP-IPN) under grants 20250110.
Data Availability Statement
The original contributions presented in the study are included in the article, further inquiries can be directed to the corresponding author.
Acknowledgments
During the preparation of this manuscript, the authors used Gemini 3 for the purposes of generate scripts for formatting figures and previous work investigation. The authors have reviewed and edited the output and take full responsibility for the content of this publication.
Conflicts of Interest
The authors declare no conflict of interest.
Abbreviations
The following abbreviations are used in this manuscript:
| ANC | Adaptive Neural Control |
| BC | Backstepping Control |
| SMC | Sliding Mode Control |
| IPC | Inverted Pendulum on a Cart |
| ITSE | Integral of Time-weighted Squared Error |
| LQR | Linear Quadratic Regulator |
| SSPF | Standard Singular Perturbation Form |
References
- Sussmann, H.J.; Yang, Y. On the stabilizability of multiple integrators by means of bounded feedback controls. In Proceedings of the 30th IEEE Conference on Decision and Control; IEEE: New York, NY, USA, 1991; pp. 70–72. [Google Scholar]
- Leomanni, M.; Costante, G.; Ferrante, F. Time-optimal control of a multidimensional integrator chain with applications. IEEE Control Syst. Lett. 2022, 6, 2371–2376. [Google Scholar] [CrossRef] [Scilit]
- Slotine, J.J.E.; Li, W. Applied Nonlinear Control; Prentice Hall: Englewood Cliffs, NJ, USA, 1991; Volume 199, p. 705. [Google Scholar]
- Spong, M.W. Modeling and control of elastic joint robots. J. Dyn. Sys. Meas. Control 1987, 109, 310–318. [Google Scholar] [CrossRef] [Scilit]
- Isidori, A. (Ed.) Nonlinear Control Systems: An Introduction; Springer: Berlin/Heidelberg, Germany, 1985. [Google Scholar]
- Teel, A.R. Global stabilization and restricted tracking for multiple integrators with bounded controls. Syst. Control Lett. 1992, 18, 165–171. [Google Scholar] [CrossRef] [Scilit]
- Mazenc, F.; Mondié, S.; Niculescu, S.I. Global asymptotic stabilization for chains of integrators with a delay in the input. IEEE Trans. Autom. Control 2003, 48, 57–63. [Google Scholar] [CrossRef] [Scilit]
- Niculescu, S.I.; Michiels, W. Stabilizing a chain of integrators using multiple delays. IEEE Trans. Autom. Control 2004, 49, 802–807. [Google Scholar] [CrossRef] [Scilit]
- Ibanez, C.A.; Frias, O.G. Controlling the inverted pendulum by means of a nested saturation function. Nonlinear Dyn. 2008, 53, 273–280. [Google Scholar]
- Villasenor Rios, C.A.; Gutiérrez-Frías, O.; Aguilar-Ibanez, C.; Suarez-Castanon, M.S. Controlling the PVTOL Aircraft System with an Inverted Pendular Load by means of Nested Saturation Functions and GPI Controller. Math. Probl. Eng. 2021, 2021, 2295417. [Google Scholar] [CrossRef] [Scilit]
- Laporte, J.; Chaillet, A.; Chitour, Y. Global stabilization of multiple integrators by a bounded feedback with constraints on its successive derivatives. In Proceedings of the 2015 54th IEEE Conference on Decision and Control (CDC); IEEE: New York, NY, USA, 2015; pp. 3983–3988. [Google Scholar]
- Saeed, A.; Behzad, A.; Mohammad, H. Dual-mode global stabilization of high-order saturated integrator chains: LMI-based MPC combined with a nested saturated feedback. Nonlinear Dyn. 2020, 102, 211–222. [Google Scholar]
- Chitour, Y.; Harmouche, M.; Laghrouche, S. Practical stabilization of perturbed integrator chains with unknown bounds. arXiv 2016, arXiv:1607.02767. [Google Scholar]
- Utkin, V.I. Sliding Modes in Control and Optimization; Springer Science and Business Media: Berlin/Heidelberg, Germany, 2013. [Google Scholar]
- Slotine, J.J.; Sastry, S.S. Tracking control of non-linear systems using sliding surfaces, with application to robot manipulators. Int. J. Control 1983, 38, 465–492. [Google Scholar] [CrossRef] [Scilit]
- Levant, A. Sliding order and sliding accuracy in sliding mode control. Int. J. Control 1993, 58, 1247–1263. [Google Scholar] [CrossRef] [Scilit]
- Shtessel, Y.; Plestan, F.; Edwards, C.; Levant, A. Adaptive sliding mode and higher order sliding-mode control techniques with applications: A survey. In Sliding-Mode Control and Variable-Structure Systems: The State of the Art; Springer International Publishing: Cham, Switzerland, 2023; pp. 267–305. [Google Scholar]
- Gaber, J. Observer-Free Sliding Mode Control via Structured Decomposition: A Smooth and Bounded Control Framework. arXiv 2025, arXiv:2508.15787. [Google Scholar]
- Narendra, K.S.; Kannan, P. Identification and control of dynamical systems using neural networks. IEEE Trans. Neural Netw. 1990, 1, 4–27. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Sanner, R.M.; Slotine, J.-J.E. Gaussian networks for direct adaptive control. IEEE Trans. Neural Netw. 1991, 3, 837–863. [Google Scholar]
- Polycarpou, M.M. Stable adaptive neural control scheme for nonlinear systems. IEEE Trans. Autom. Control 2002, 41, 447–451. [Google Scholar]
- Lewis, F.L.; Liu, K.; Yesildirek, A. Neural net robot controller with guaranteed tracking performance. IEEE Trans. Neural Netw. 1995, 6, 703–715. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Volyanskyy, K.Y.; Haddad, W.M.; Calise, A.J. A New Neuroadaptive Control Architecture for Nonlinear Uncertain Dynamical Systems: Beyond σ-and e-Modifications. IEEE Trans. Neural Netw. 2009, 20, 1707–1723. [Google Scholar] [PubMed]
- Hayakawa, T.; Haddad, W.M.; Hovakimyan, N. Neural network adaptive control for nonlinear uncertain dynamical systems with asymptotic stability guarantees. In Proceedings of the 2005, American Control Conference, 2005; IEEE: New York, NY, USA, 2005. [Google Scholar]
- Yañez Badillo, H.; Tapia-Olvera, R.; Aguilar-Mejía, O.; Beltran-Carbajal, F. Control neuronal en línea para regulación y seguimiento de trayectorias de posición para un quadrotor. Rev. Iberoam. Autom. Inform. Ind. RIAI 2017, 14, 141–151. [Google Scholar] [CrossRef] [Scilit]
- Saini, K.; Kumar, N.; Bhushan, B.; Kumar, R. Artificial neural network-based adaptive control for nonlinear dynamical systems. Int. J. Adapt. Control Signal Process. 2024, 38, 2693–2715. [Google Scholar]
- Rai, A.; Bhushan, B.; Jaint, B. Design of a Novel Recurrent Neural Network Model for Identification and Adaptive Control of Dynamical Systems. Int. J. Robust Nonlinear Control 2025, 35, 7817–7836. [Google Scholar] [CrossRef] [Scilit]
- Li, Y.; Zhang, J.; Xu, X.; Chin, C.S. Adaptive fixed-time neural network tracking control of nonlinear interconnected systems. Entropy 2021, 23, 1152. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Yagiz, N.; Hacioglu, Y. Backstepping control of a vehicle with active suspensions. Control Eng. Pract. 2008, 16, 1457–1467. [Google Scholar] [CrossRef] [Scilit]
- Ge, S.S.; Wang, C. Direct adaptive NN control of a class of nonlinear systems. IEEE Trans. Neural Netw. 2002, 13, 214–221. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Li, Y.; Qiang, S.; Zhuang, X.; Kaynak, O. Robust and adaptive backstepping control for nonlinear systems using RBF neural networks. IEEE Trans. Neural Netw. 2004, 15, 693–701. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Wang, D.; Huang, J. Neural network-based adaptive dynamic surface control for a class of uncertain nonlinear systems in strict-feedback form. IEEE Trans. Neural Netw. 2005, 16, 195–202. [Google Scholar] [PubMed]
- Chen, M.; Tao, G.; Jiang, B. Dynamic surface control using neural networks for a class of uncertain nonlinear systems with input saturation. IEEE Trans. Neural Netw. Learn. Syst. 2014, 26, 2086–2097. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Li, K.; Li, Y. Adaptive neural network finite-time dynamic surface control for nonlinear systems. IEEE Trans. Neural Netw. Learn. Syst. 2020, 32, 5688–5697. [Google Scholar] [CrossRef] [Scilit]
- Jia, S.; Wang, H.; Liu, S. Backstepping-based Dynamic Surface Control of Discrete-time Nonlinear Systems. IFAC-PapersOnLine 2024, 58, 130–135. [Google Scholar]
- Kokotović, P.; Khalil, H.K.; O’reilly, J. Singular Perturbation Methods in Control: Analysis and Design; Society for Industrial and Applied Mathematics: Philadelphia, PA, USA, 1999. [Google Scholar]
- Khalil, H.K.; Minor, M. Nonlinear Control; Pearson: Sydney, Australia, 2015; pp. 423–460. [Google Scholar]
- Ioannou, P.A.; Kokotovic, P.V. (Eds.) Adaptive Systems with Reduced Models; Springer: Berlin/Heidelberg, Germany, 1983. [Google Scholar]
- Atassi, A.N.; Khalil, H.K. A separation principle for the stabilization of a class of nonlinear systems. IEEE Trans. Autom. Control 2002, 44, 1672–1687. [Google Scholar]
- Mohan Rayguru, M.; Ramalingam, B.; Rajesh Elara, M. A singular perturbation based adaptive strategy for bounded controller design in feedback linearizable systems. Int. J. Adapt. Control Signal Process. 2022, 36, 264–281. [Google Scholar]
- Rayguru, M.M.; Kar, I.N. A singular perturbation approach to saturated controller design with application to bounded stabilization of wing rock phenomenon. Nonlinear Dyn. 2018, 93, 2263–2272. [Google Scholar] [CrossRef] [Scilit]
- Lozano, R.; Dimogianopoulos, D. Stabilization of a chain of integrators with nonlinear perturbations: Application to the inverted pendulum. In Proceedings of the 42nd IEEE International Conference on Decision and Control (IEEE Cat. No. 03CH37475); IEEE: New York, NY, USA, 2003; Volume 5. [Google Scholar]

Disclaimer/Publisher’s Note: The statements, opinions and data contained in all publications are solely those of the individual author(s) and contributor(s) and not of MDPI and/or the editor(s). MDPI and/or the editor(s) disclaim responsibility for any injury to people or property resulting from any ideas, methods, instructions or products referred to in the content. |
© 2026 by the authors. Licensee MDPI, Basel, Switzerland. This article is an open access article distributed under the terms and conditions of the Creative Commons Attribution (CC BY) license.