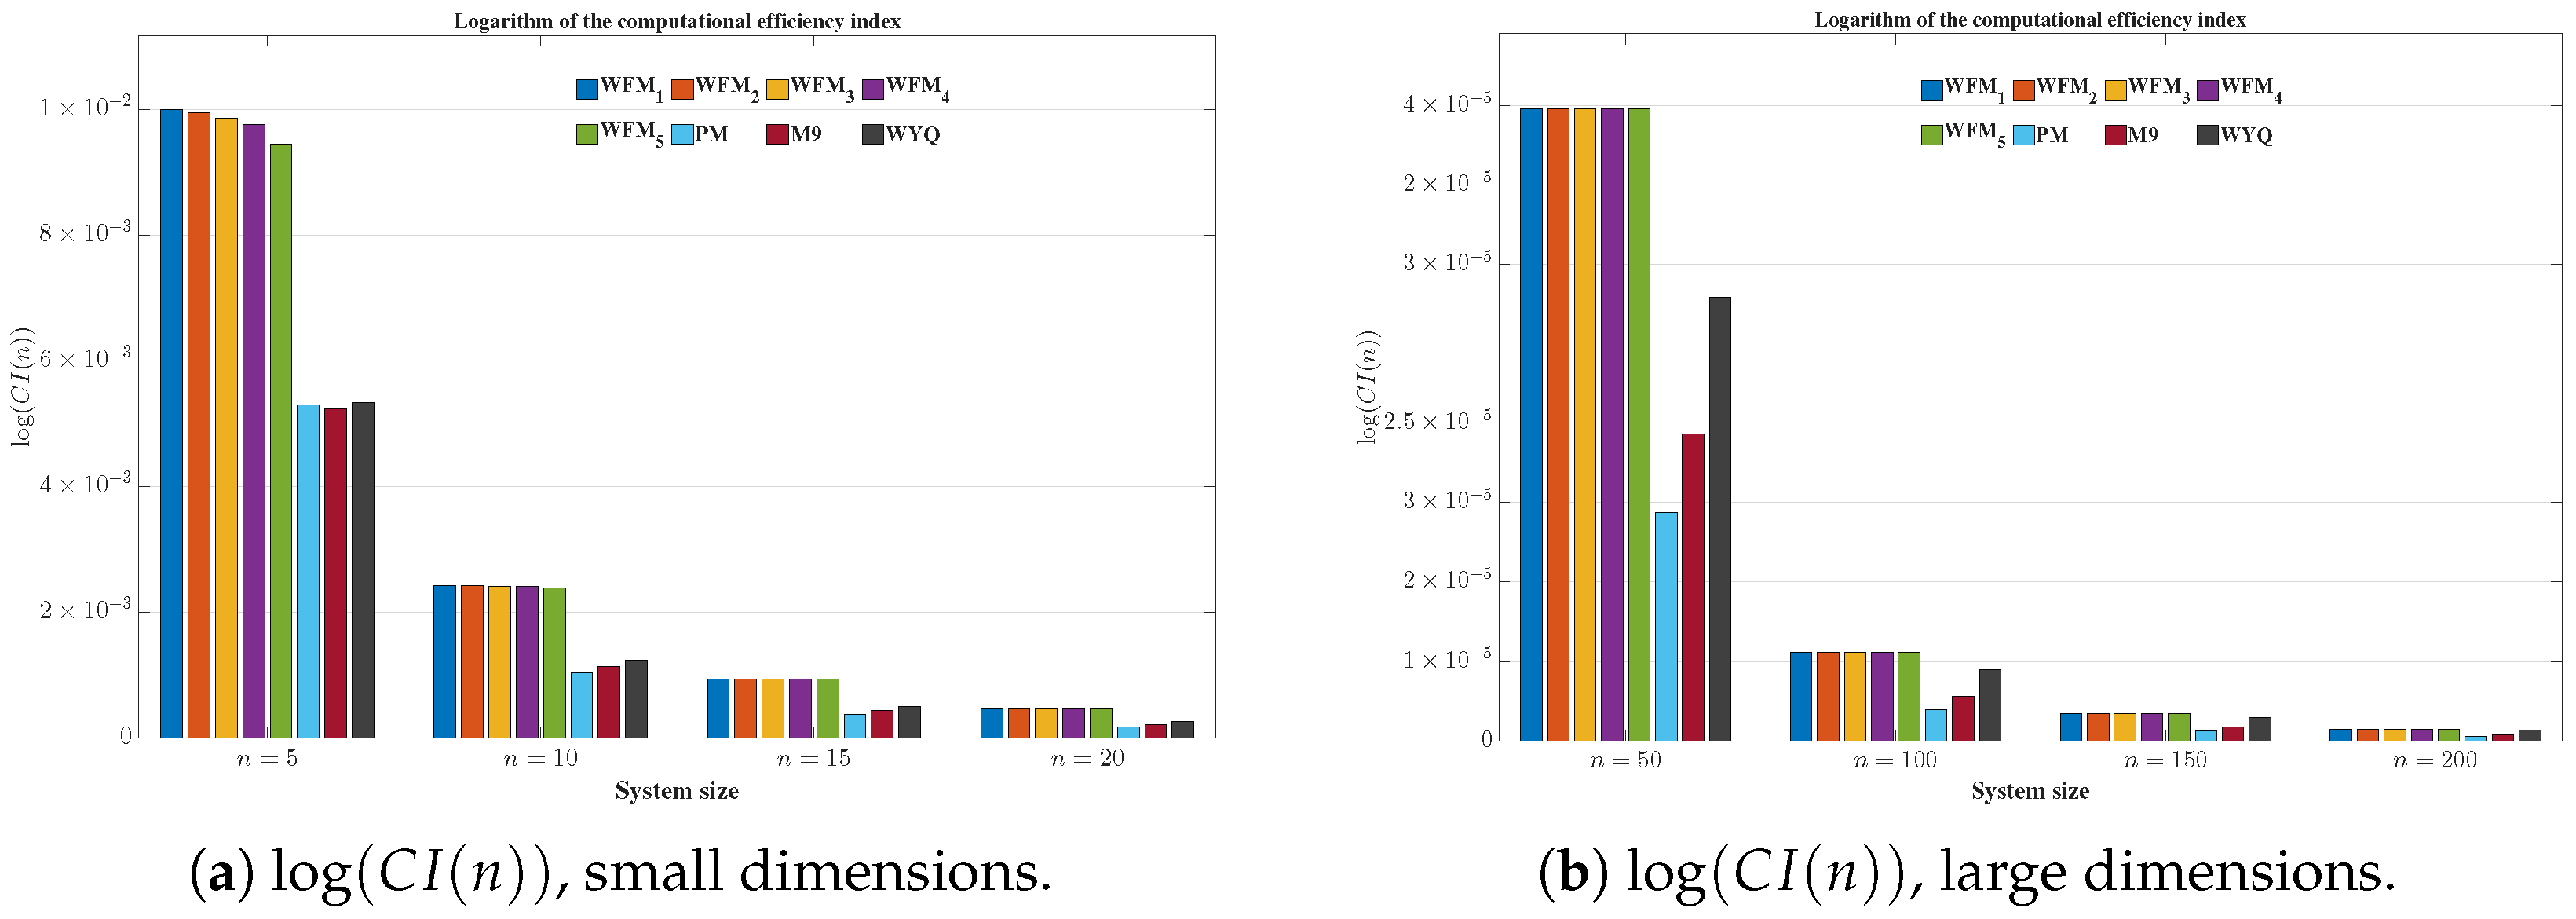1. Introduction
The numerical solution of nonlinear systems is a central problem in scientific computing, since many mathematical models arising in engineering, mechanics, fluid dynamics, electromagnetism, and reaction–diffusion theory ultimately require the approximation of roots of nonlinear equations. In practice, such systems frequently appear after the discretization of differential, integro-differential, or variational models. Let
be a sufficiently smooth mapping. We consider the nonlinear system
To make this general formulation more explicit, one may think of nonlinear systems in both algebraic and discretized forms. A simple two-dimensional prototype is
where polynomial and transcendental nonlinearities are coupled in the same system. More demanding examples arise from classical boundary value models, such as Bratu-type or reaction–diffusion problems,
or from nonlinear Fredholm integral equations of the form
After finite-difference or quadrature discretization, these models lead to nonlinear algebraic systems whose dimension may be large and whose Jacobian matrices may be dense, sparse, ill-conditioned, or expensive to factorize. Consequently, the main computational difficulties are not limited to the existence of nonlinearities; they also include the cost of Jacobian evaluations, the solution of linear systems at each iteration, sensitivity to starting points, and the need to preserve stability while increasing the convergence order.
Therefore, the construction of iterative methods with a high local order of convergence, controlled computational cost, and reliable numerical stability continues to be an active research topic. Classical references such as Traub’s monograph and the book by Ortega and Rheinboldt provide the foundational framework for the analysis of Newton-type schemes and their variants [
1,
2].
For nonlinear systems, Newton’s method remains the natural benchmark due to its quadratic local convergence and structural simplicity. This method is given by
In the vectorial setting, Newton’s scheme is also regarded as the first optimal procedure: it attains order two using one evaluation of the Jacobian matrix and one evaluation of the nonlinear function per iteration. However, increasing the order of convergence without significantly increasing the number of Jacobian evaluations, matrix factorizations, or functional evaluations constitutes a major challenge. This issue is especially relevant in the multidimensional case, where the cost associated with linear algebra operations may dominate the overall performance of the iterative process.
The scalar optimality criterion introduced by Kung and Traub [
3] motivates, in the vectorial case, an analogous way of measuring optimality according to the number of Jacobian and function evaluations required per iteration. This vectorial optimality criterion will be formally recalled below in Conjecture [
4], and it will be used in this work as the reference framework to assess the optimal character of the proposed methods.
Under this criterion, Newton’s method corresponds to the first optimal case, of order two. The next relevant milestone is the construction of optimal fourth-order procedures with , and the subsequent target is the construction of optimal eighth-order procedures with .
The development of methods attaining the vectorial optimality bound has been gradual and remains limited. After Newton’s method, the construction of optimal fourth-order procedures with
represents the natural intermediate step toward eighth-order schemes with
. More recently, Cordero, Torregrosa and Triguero-Navarro established the first optimal vectorial eighth-order iterative scheme for solving nonlinear systems, thereby reaching the next level in the Cordero–Torregrosa hierarchy [
5].
The literature on high-order iterative methods for nonlinear systems has grown steadily in recent years. Representative contributions include Jarratt-like fourth- and sixth-order methods [
6], families of fourth- and sixth-order methods together with efficiency and dynamical analyses [
7], techniques for systematically increasing the order of convergence of iterative schemes [
8], efficient high-order methods for large-scale nonlinear systems [
9], semilocal convergence analyses for eighth-order schemes [
10], and related developments for structured nonlinear systems [
11]. These works show that the field has evolved from fixed multipoint formulas toward more flexible constructions involving accelerators, free parameters, semilocal theory, and dynamical tools.
A particularly fruitful line of research in this context concerns the design of high-order methods through scalar accelerators, parametric families, and weight-function-based techniques for nonlinear systems. Among these strategies, scalar accelerators constructed from quotients of squared norms, for instance
where
is an intermediate approximation generated by Newton’s method, have been shown to increase the convergence order without requiring additional functional evaluations. This idea is also related to recent Traub-type constructions for nonlinear systems [
12]. However, although the first optimal vectorial eighth-order scheme was recently obtained in [
5], the systematic construction of optimal eighth-order families for nonlinear systems by means of weight functions remains, to the best of our knowledge, an open and relevant direction.
Motivated by these considerations, in this work, we introduce a third correction step based on multivariable scalar weight functions, giving rise to new families of optimal eighth-order methods for nonlinear systems. The proposed framework contains, as a particular member, the optimal eighth-order scheme introduced in [
5]. The weight functions are designed through suitable Taylor conditions so that the lower-order error terms are canceled and eighth-order convergence is preserved. Since the resulting methods require one Jacobian evaluation and three evaluations of
F per iteration, they attain the Cordero–Torregrosa bound. Consequently, the proposed schemes are optimal in the vectorial sense.
The main contribution of this paper is, therefore, twofold. First, it provides a general framework based on weight functions that extends the first optimal vectorial eighth-order scheme from an isolated iterative process to a family of methods. Second, to the best of our knowledge, it presents the first family of optimal eighth-order methods for nonlinear systems, in the sense of the Cordero–Torregrosa conjecture, obtained by means of the weight-function technique. This point distinguishes the present work from previous optimal constructions and connects directly with the role of weight functions as a flexible tool for preserving high-order convergence without increasing the evaluation cost.
The convergence analysis combines Taylor expansions of the nonlinear operator and its Fréchet derivative with expansions of the inverse Jacobian and of the scalar accelerators involved in the correction terms. As a result, explicit sufficient conditions on the weight functions are derived to guarantee eighth-order convergence for nondegenerate solutions. In addition, the computational efficiency of the proposed families is analyzed and compared with that of several existing high-order iterative schemes.
Beyond their theoretical interest, the proposed schemes are relevant for applications requiring highly accurate solutions of nonlinear algebraic systems. In particular, nonlinear systems arising from quadrature discretizations of Fredholm integral equations and from finite-difference discretizations of semilinear elliptic boundary value problems provide natural and meaningful testing environments since they combine nonlinearity, a dense or sparse algebraic structure, and practical computational demands.
The remainder of the paper is organized as follows. In
Section 2, we introduce the notation and preliminary expansions required for the convergence analysis.
Section 3 is devoted to the construction of the proposed family with weight functions and to the derivation of sufficient conditions on the weight functions that guarantee optimal eighth-order convergence. In
Section 4, we present the computational efficiency analysis and numerical experiments on several nonlinear systems, including a nonlinear Fredholm integral equation.
Section 5 deals with the application of the proposed methods to nonlinear systems arising from the finite-difference discretization of a two-dimensional semilinear elliptic Dirichlet problem.
2. Preliminary Concepts
Let
be a sufficiently smooth nonlinear operator defined on an open convex domain,
. Throughout this work, we assume that the nonlinear system
has a solution
, such that
is nonsingular. In this case,
is referred to as a nondegenerate solution of the nonlinear system. All derivatives required in the subsequent local analysis are assumed to exist and to be continuous in a neighborhood of
.
For the convergence analysis, we use the standard multilinear notation for higher-order Fréchet derivatives. For
, the
m-th derivative of
F at
x is regarded as the
m-linear mapping
For
, we write
and, in the repeated-argument case,
If one of the arguments is itself a higher-order derivative term, we use the compact convention
Let
, where
is sufficiently small. Since
is invertible, the Taylor expansion of
F around
can be written as
where
and
is regarded as a
j-linear operator from
into
.
Here and throughout the paper, expressions involving the operators are understood according to the multilinear notation introduced above.
The corresponding expansion of the Jacobian is
Consequently, the inverse Jacobian admits the Neumann-type expansion
For an iterative sequence,
, converging to
, the local error is denoted by
Definition 1 ([
13])
. The sequence is said to converge locally to ξ with order if there exists a nonzero p-linear operator , such thatThe operator determines the leading term of the local error equation. In the numerical section, the observed convergence order is estimated by means of the approximated computational order of convergence.
Conjecture 1 (Cordero–Torregrosa [
4])
. Let be a nonlinear system, and consider an iterative procedure without memory designed to approximate its solutions. Suppose that, at each iteration, the scheme requires evaluations of the Jacobian matrix and evaluations of the map , where . Then, the attainable local order of convergence p is bounded byThe method is said to be optimal precisely when this bound is attained, i.e., when Definition 2 ([
14])
. The approximated computational order of convergence (ACOC) is defined as Finally, since the proposed methods are constructed by weight-function correction steps, we specify the meaning of a weight function in the present framework.
A weight function is an auxiliary scalar-, vector-, or matrix-valued mapping introduced into an iterative scheme to modify one or more correction terms. Its role is to impose suitable cancellations in the local error equation, thereby increasing the convergence order while preserving, as far as possible, the computational efficiency of the method.
4. Numerical Experiments
This section presents the numerical assessment of the proposed weight-function family and its comparison with three reference schemes, denoted by PM, M9, and WYQ. The comparison is developed from two complementary perspectives. First, we analyze the computational cost per iteration by means of a computational efficiency index adapted to nonlinear systems. Second, we evaluate the practical performance of the methods on several nonlinear systems of a different structure and dimension.
Throughout this section, the notation – is used for the five selected members of the proposed weight-function family.
4.1. Methods Under Comparison
The proposed methods
–
are obtained from the weight-function family introduced in Theorem 1. The corresponding choices of the weight functions are listed in
Table 1. In the parametric case
, we fix
throughout the numerical study.
The selected members in
Table 1 were chosen to represent increasing levels of algebraic complexity while preserving the same evaluation structure of the proposed family. Thus,
is the simplest reference member,
introduces the lowest-order admissible perturbation in
H,
and
test non-polynomial exponential and rational weights, and
represents a parametric combination of admissible higher-order terms. Since these additional terms depend only on the scalar accelerators
,
,
, and
, they do not require new evaluations of
F or
; their effect is reflected only in the algebraic cost constants
.
The benchmark methods used in the comparison are the ninth-order method PM proposed by Behl et al. [
9], the ninth-order method M9 proposed by Xiao [
8], and the eighth-order method WYQ proposed by Wang, Yang and Qin [
10]. For completeness, their iterative expressions are recalled below.
The PM method is given by
For the M9 method, let
and define
Then, the method can be written as
The WYQ method is given by
where
4.2. Computational Cost and Efficiency Index
The classical efficiency index is defined by
where
p denotes the order of convergence, and
d is the number of functional evaluations per iteration. For nonlinear systems, however, the dominant computational effort is usually associated with linear algebra operations, such as matrix factorizations, linear solves, and matrix–vector products. Therefore, we use the computational efficiency index
where
is the total cost per iteration. Here,
denotes the functional-evaluation cost and
denotes the number of products and quotients.
The following cost model is adopted:
One evaluation of F requires n scalar functional evaluations;
One evaluation of requires scalar functional evaluations;
One inner product in requires n scalar products;
One matrix–vector product of size requires scalar products;
The solution of
m linear systems with the same coefficient matrix, using one
factorization, followed by
m forward/back substitutions, requires
products and quotients.
Additions and subtractions are not included in the count.
The structural counts per iteration are summarized in
Table 2. Here,
denotes the number of
factorizations,
the number of linear solves,
the number of matrix–vector products, and
the number of inner products.
For each proposed method,
, the functional-evaluation cost is
whereas, for the benchmark methods,
The four scalar accelerators , , , and require four inner products and four scalar quotients. Only the inner products contribute a term proportional to n, whereas the scalar quotients are absorbed into the constant term .
For the proposed methods, the LU factorization, together with the three triangular solves, contributes
The four inner products defining the scalar accelerators contribute
products, and the scalar–vector products appearing in the second and third correction steps contribute
additional products. Hence, the total linear contribution is
The remaining scalar quotients and the additional scalar products required by each particular weight function are collected in the constants
listed in
Table 1. These constants are not parameters of the iterative schemes but bookkeeping terms in the operation count. More precisely, once the scalar accelerators
,
,
, and
have been computed,
accounts for the fixed number of scalar products, quotients, and powers needed to evaluate the specific functions
H,
, and
G associated with
. Hence,
is deduced directly from the algebraic form of the weight functions in
Table 1. Since these operations do not depend on the dimension
n,
contributes only to the constant term of the total cost and does not affect the asymptotic efficiency ranking.
For M9, one factorization is associated with
and another one with
. Taking into account the eight linear solves, two matrix–vector products, and the scalar–vector products involved in the last two corrections, one obtains
and, hence,
For WYQ, the factorization of
is reused throughout the whole iteration. The method requires seven linear solves, four matrix–vector products, and two scalar–vector multiplications. Therefore,
and
The resulting expressions for
,
,
, and
are collected in
Table 3.
The constants
modify only the
term in the total cost and do not alter the asymptotic comparison with the benchmark methods. Hence,
Moreover, since the five selected members of the weight-function family differ only in the constant term of
, their internal asymptotic ranking is
This theoretical analysis shows that the proposed family preserves eighth-order convergence while exhibiting the most favorable asymptotic cost profile among the methods considered here.
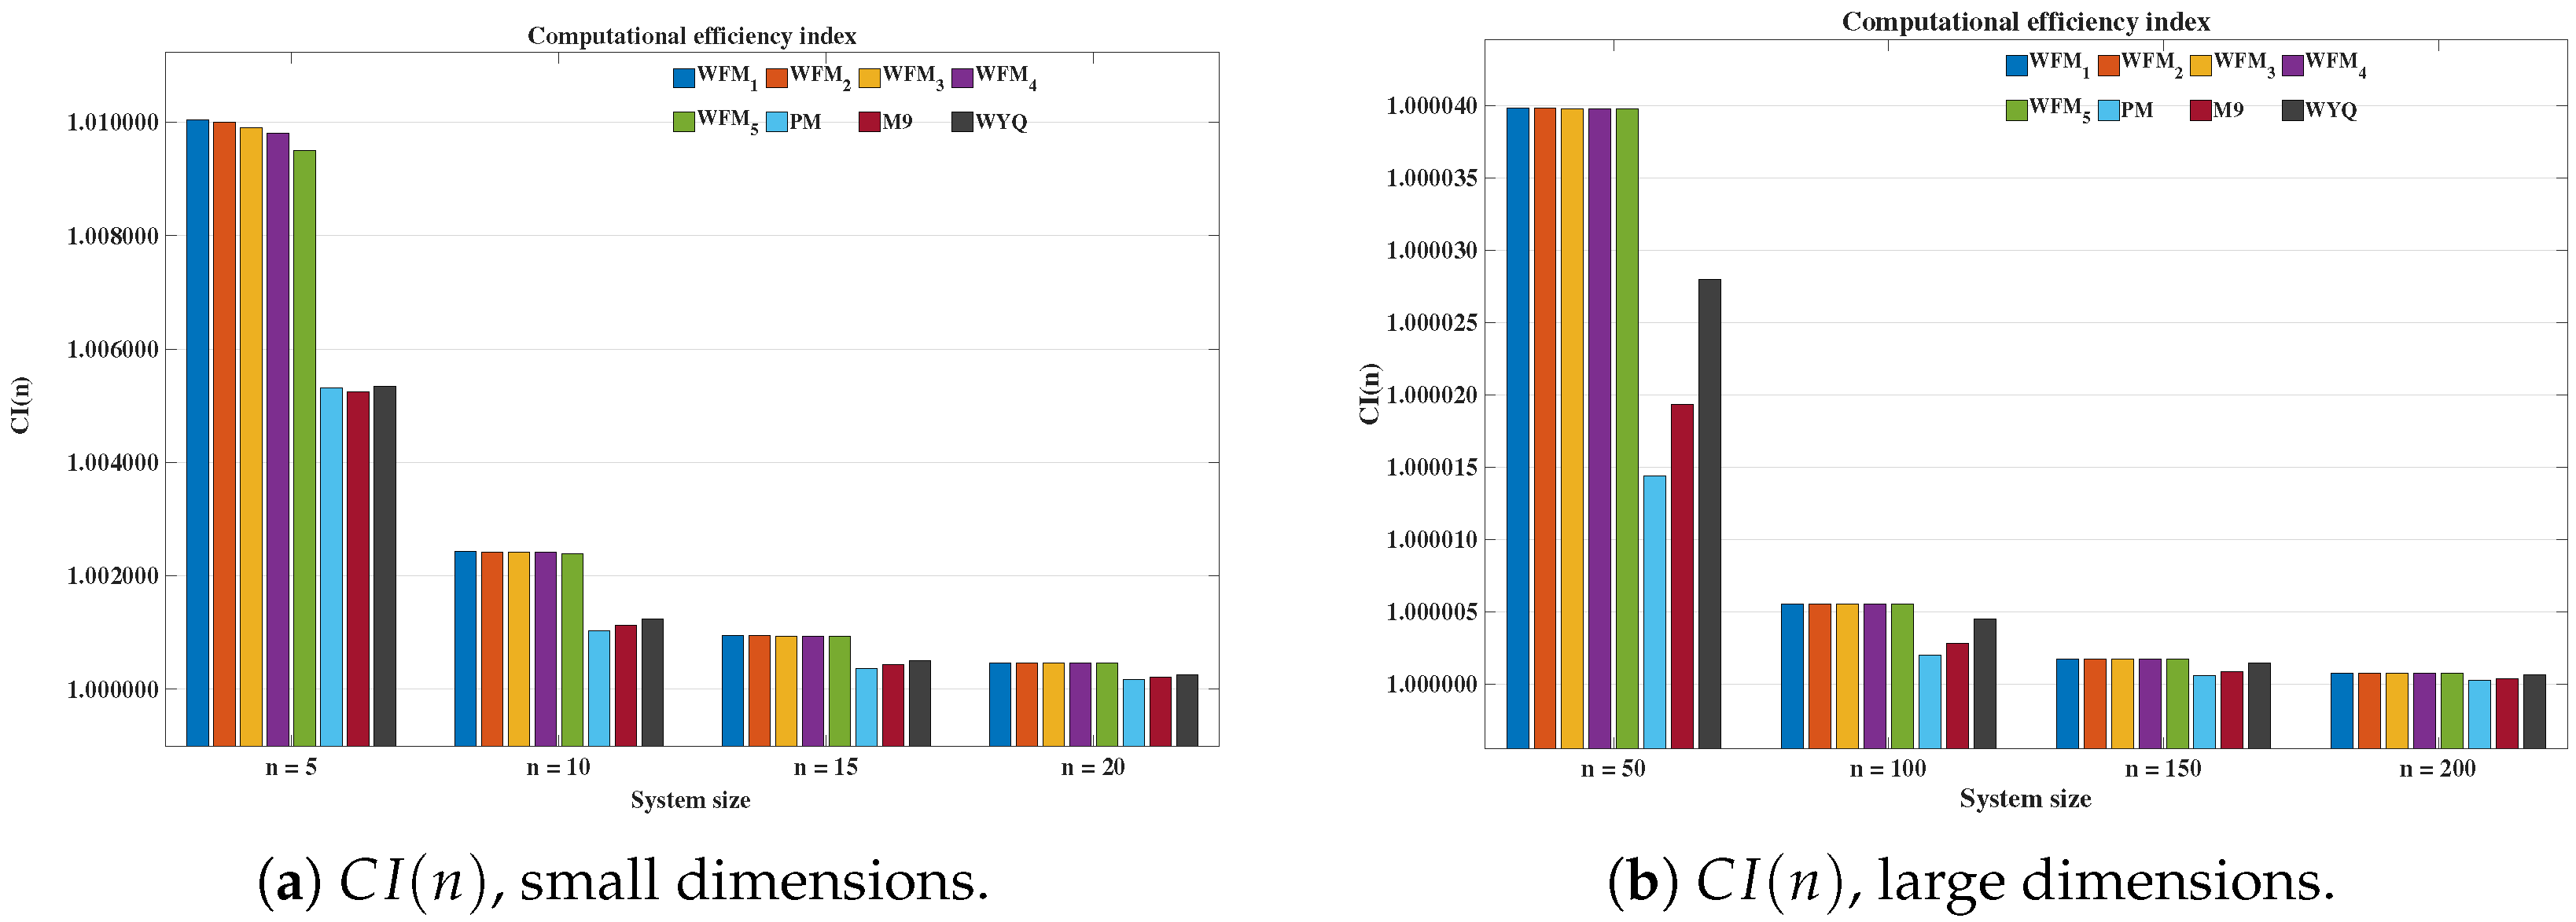
The computational efficiency index
for small and large nonlinear systems is shown in
Figure 1. The logarithmic representation of this index is presented in
Figure 2, which makes the differences between the methods more visible for large dimensions.
As shown in
Figure 1a,b and
Figure 2a,b, the proposed methods
,
, consistently attain higher computational efficiency indices than the benchmark methods
,
, and
. This superiority is visually reflected in the larger bar heights of the
methods for both small and large systems. The logarithmic plots confirm the same trend, reinforcing the computational advantage of the proposed family under the adopted cost model.
4.3. Test Problems and Numerical Results
In this subsection, we evaluate the numerical performance of – and compare them with PM, M9, and WYQ on five nonlinear systems of different dimensions and structures. The selected tests include dense, cyclic, transcendental, and large-scale nonlinear systems, providing a representative framework for assessing accuracy, convergence behavior, and computational cost.
For each method and test problem, the tables report the number of iterations, the norm of the last correction
the residual norm
the CPU time, and the approximated computational order of convergence (ACOC). A dash symbol, “–”, indicates that the ACOC estimator did not provide a stable representative value in the last iterations.
The stopping criterion used in all tests was
with a maximum of 50 iterations. All computations were carried out in MATLAB R2025b Update 5 using
vpa (variable-precision arithmetic) through with 2000 decimal digits. This high-precision setting was used to reduce round-off effects and to observe the asymptotic behavior of the methods more reliably.
For each nonlinear system, all methods were tested from the same initial approximation. To obtain representative timing data, each method was executed 10 times, and the CPU time reported in the tables corresponds to the average value. The computations were performed on a computer running macOS Tahoe, version 26.3, equipped with an Apple M2 processor and 8 GB of LPDDR5 RAM.
Example 1. For the first numerical test, we consider the following nonlinear system of dimension : The initial approximation is taken as Example 2. As a second test problem, we consider a nonlinear system of dimension : The starting vector is chosen as Example 3. For the third numerical example, we employ the cyclic logarithmic system with : The initial approximation is Example 4. The fourth test problem is the following the atan-quadratic system of dimension : We take as initial approximation Example 5. Finally, we consider the exponential system with dimension : The initial vector is selected as Table 4,
Table 5,
Table 6,
Table 7 and
Table 8 collect the numerical performance of
–
, PM, M9 and WYQ for the nonlinear systems described in Examples 1–5. The purpose of these experiments is to compare not only final accuracy and observed convergence order but also the computational time required to reach the prescribed tolerance.
The results in
Table 4 show that all methods solve the first problem with very high accuracy. The proposed WFM methods reach the prescribed tolerance in four iterations, with ACOC values close to the theoretical order of eight. Although PM and M9 attain smaller final residuals, their CPU times are considerably larger. In particular,
–
require approximately 14–16 s, whereas PM, M9 and WYQ require approximately 49, 28 and 20 s, respectively. Therefore, for this test, the proposed weight-function family provides a favorable balance between accuracy, observed convergence order and computational cost.
For Example 2,
Table 5 shows that all WFM methods converge in four iterations and their ACOC values confirm the eighth local order established in Theorem 1. They also require lower CPU times than the reference methods. In particular,
and
are the fastest variants, with approximately
and
s, respectively, compared with
,
, and
s for PM, M9, and WYQ. Hence, the proposed schemes preserve high accuracy while reducing computational time.
Table 6 shows the results for the large-scale cyclic logarithmic system with
. The WFM methods converge in four iterations and their ACOC values confirm the eighth local order established in Theorem 1. In terms of CPU time, the proposed schemes require about 91–98 s, clearly improving on PM, M9 and WYQ, which require approximately 184, 153 and 142 s, respectively. Hence, the WFM family is especially competitive for this large-scale problem.
The results in
Table 7 show that the proposed methods also perform well on the atan-quadratic system. All WFM variants converge in four iterations and produce ACOC values practically equal to eight. Their CPU times are significantly lower than those of the comparison methods: the WFM schemes take approximately 155–162 s, whereas PM, M9 and WYQ require about 255, 337 and 238 s, respectively. Hence, although the reference methods reach very small residuals, the weight-function family achieves the required accuracy with a substantially lower computational cost.
For the exponential system in Example 5,
Table 8 shows that all methods converge in three iterations. The WFM schemes require approximately 88–90 s, whereas PM, M9 and WYQ require about 163, 225 and 153 s, respectively, showing a clear advantage in CPU time.
Overall,
Table 4,
Table 5,
Table 6,
Table 7 and
Table 8 confirm that the proposed WFM methods are highly competitive. They achieve high accuracy in terms of correction norms and residuals, while consistently requiring less CPU time than the reference schemes.
Numerical Test on a Fredholm Integral Equation
We complement the previous algebraic tests by considering a nonlinear Fredholm integral equation. After quadrature discretization, this problem leads to a dense nonlinear algebraic system whose structure differs from the polynomial, transcendental, and cyclic systems analyzed above. Therefore, it provides an additional benchmark for assessing the practical behavior of the proposed methods – and the reference schemes PM, M9, and WYQ.
Example 6 (Nonlinear Fredholm integral equation)
. We consider the nonlinear Fredholm integral equation of the second kind,This problem has been used as a benchmark in the numerical analysis of high-order iterative methods for nonlinear systems [7]. Moreover, the continuous problem admits the exact solution,sinceFor the numerical discretization, we take and introduce the uniform nodesThe integral in (
48)
is approximated by the composite Simpson rule. Since is even, the rule can be applied directly. The unknowns are denoted byand we write The node is not included as an unknown because the factor s in the kernel makes its contribution vanish. Thus, the discretization of (
48)
gives the nonlinear algebraic systemwhere the Simpson weights are given by The Jacobian matrix associated with (
49)
iswhere denotes the Kronecker delta. In the numerical experiment, all methods are initialized withThe stopping criterion, tolerance, maximum number of iterations, precision setting, CPU-time averaging procedure, and ACOC estimator are the same as those described in Section 4.3. The computed discrete solution can be represented in compact form asIn particular, The resulting nonlinear system has a dimension of 50 and dense coupling induced by the quadrature approximation of the integral term. This makes the problem suitable for comparing the robustness and efficiency of – against PM, M9, and WYQ.
For this Fredholm test problem,
Table 9 reports the main numerical output of each method: the number of iterations, the norm of the final increment
, the final residual norm
, the averaged CPU time, and the ACOC value.
The results in
Table 9 show that all methods solve the Fredholm test problem with very small final increments and residual norms. The proposed
–
schemes converge in four iterations and exhibit ACOC values that confirm the eighth local order established in Theorem 1. Although PM and M9 achieve smaller residuals, their CPU times are substantially larger. In particular, the WFM methods require approximately 11–12 s, whereas PM, M9, and WYQ require approximately
,
, and
s, respectively. Thus, the proposed family provides a favorable balance between accuracy, confirmed local order, and computational time for this dense Fredholm discretization.
6. Conclusions
The numerical experiments carried out in this work support the theoretical performance of the proposed schemes on nonlinear systems of different dimensions and structures. In addition, the proposed weight-function family generalizes the original CTT8 method, which is recovered as a particular member through a suitable choice of the weight functions. Therefore, the present construction extends the CTT8 scheme from an isolated optimal eighth-order method to a broader family of optimal iterative procedures for nonlinear systems.
The new schemes are competitive in terms of residual accuracy, correction norm, and computational efficiency. The Fredholm integral equation and the semilinear elliptic Dirichlet problem further illustrate the reliability and computational performance of the methods when applied to nonlinear systems arising from numerical discretizations.
The theoretical contribution of the paper can be summarized as follows. Starting from a Newton-type predictor and a fourth-order correction, we introduced a third correction step governed by multivariable scalar weight functions. Suitable Taylor conditions on these functions were derived in order to cancel all error terms up to order seven. As a consequence, the resulting schemes attain eighth-order local convergence for nondegenerate solutions. Since the methods require one Jacobian evaluation and three evaluations of the nonlinear operator per iteration, they attain the Cordero–Torregrosa optimal bound for nonlinear systems.
The use of weight functions is important because it changes the role of the original CTT8 method. Instead of having a single eighth-order optimal scheme, the proposed construction provides a whole admissible family. This makes it possible to introduce polynomial, exponential, rational, and parametric perturbations without increasing the number of evaluations of F or . Therefore, the weight-function framework offers flexibility while preserving the same optimal convergence structure.
From the computational point of view, the cost analysis shows that the proposed WFM methods have a favorable efficiency profile when compared with the reference schemes PM, M9, and WYQ. The performance curves for small and large dimensions confirm that the proposed methods preserve eighth-order convergence with a lower asymptotic cost, mainly because they reuse a single Jacobian factorization throughout the iteration. Among the selected members, WFM1 has the lowest algebraic overhead, whereas the remaining WFM variants illustrate that more elaborate admissible weight functions can be incorporated with only a small constant increase in cost.
The numerical examples confirm the theoretical conclusions. For the finite-dimensional nonlinear test systems, the proposed methods reach very small correction norms and residual norms, and the observed values of the approximated computational order of convergence agree with the expected eighth order. These results indicate that the theoretical error analysis is reflected in the practical behavior of the schemes.
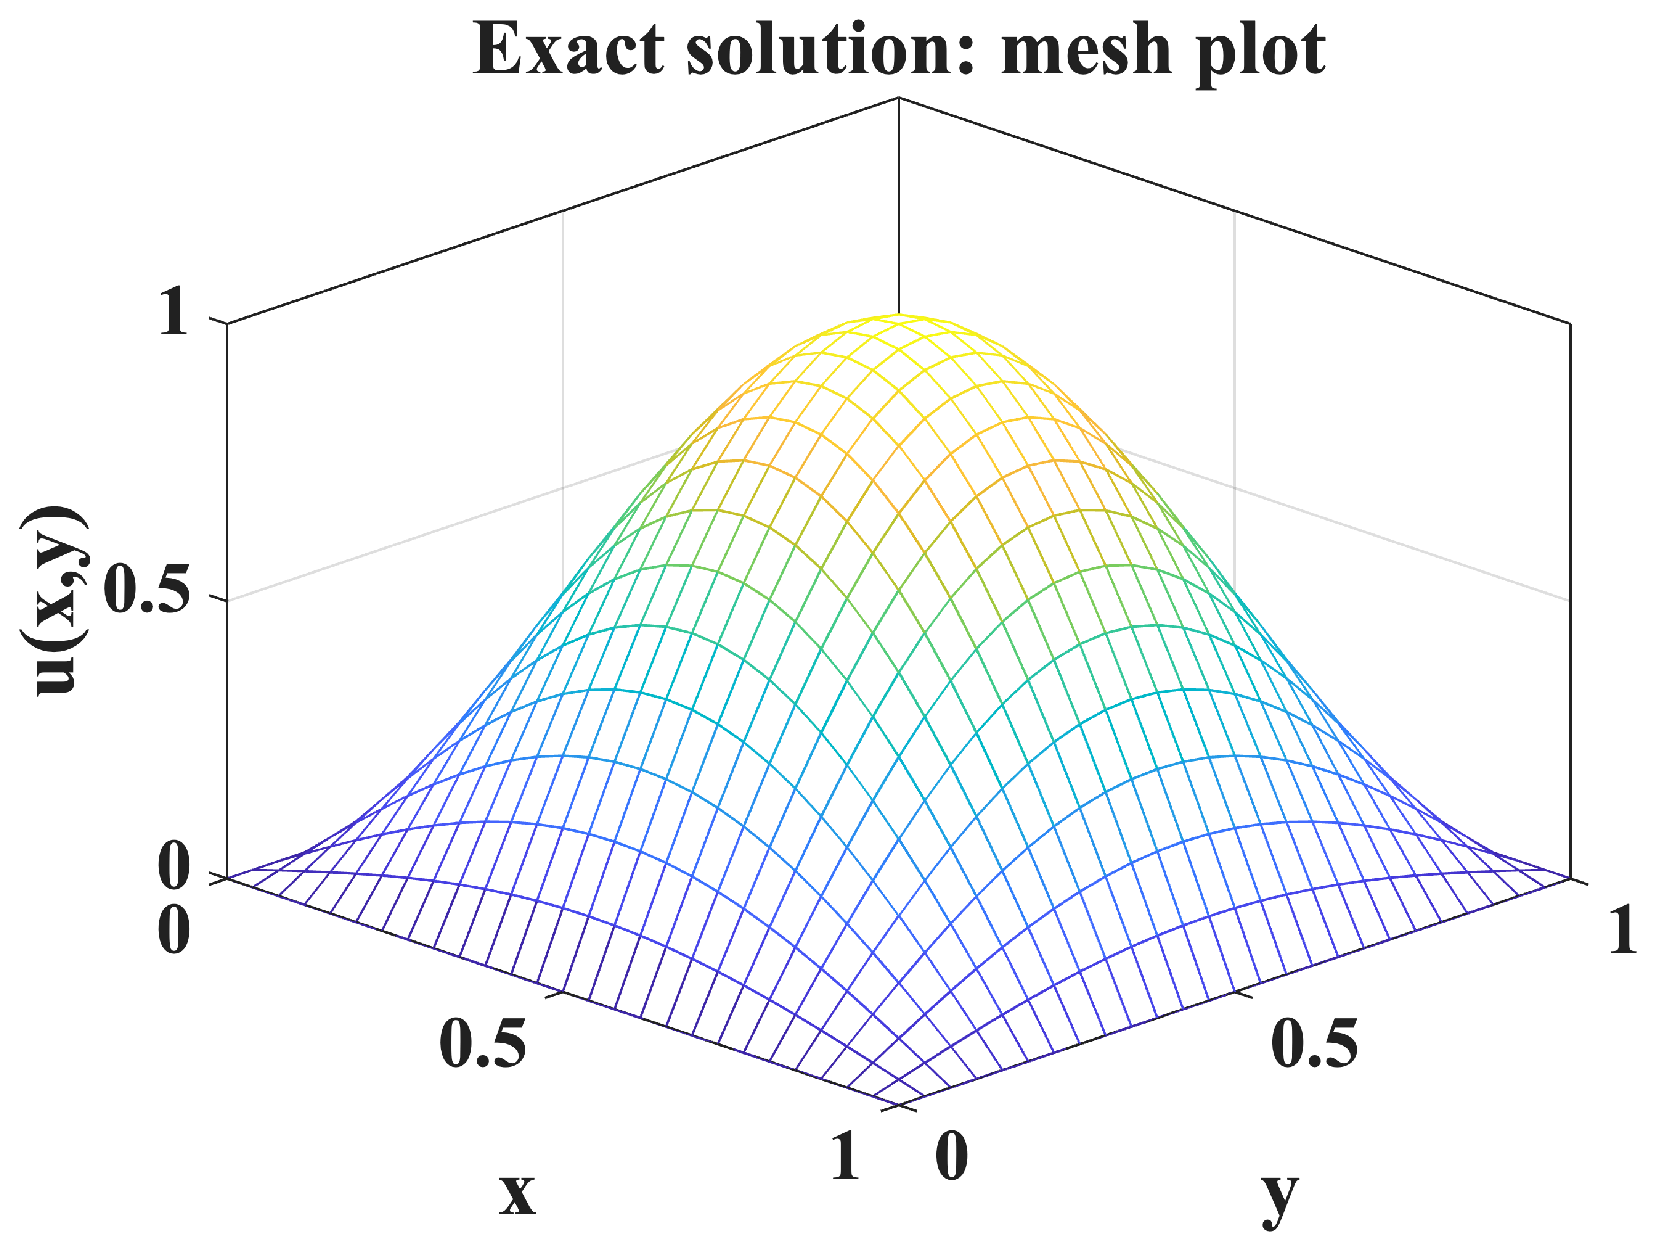
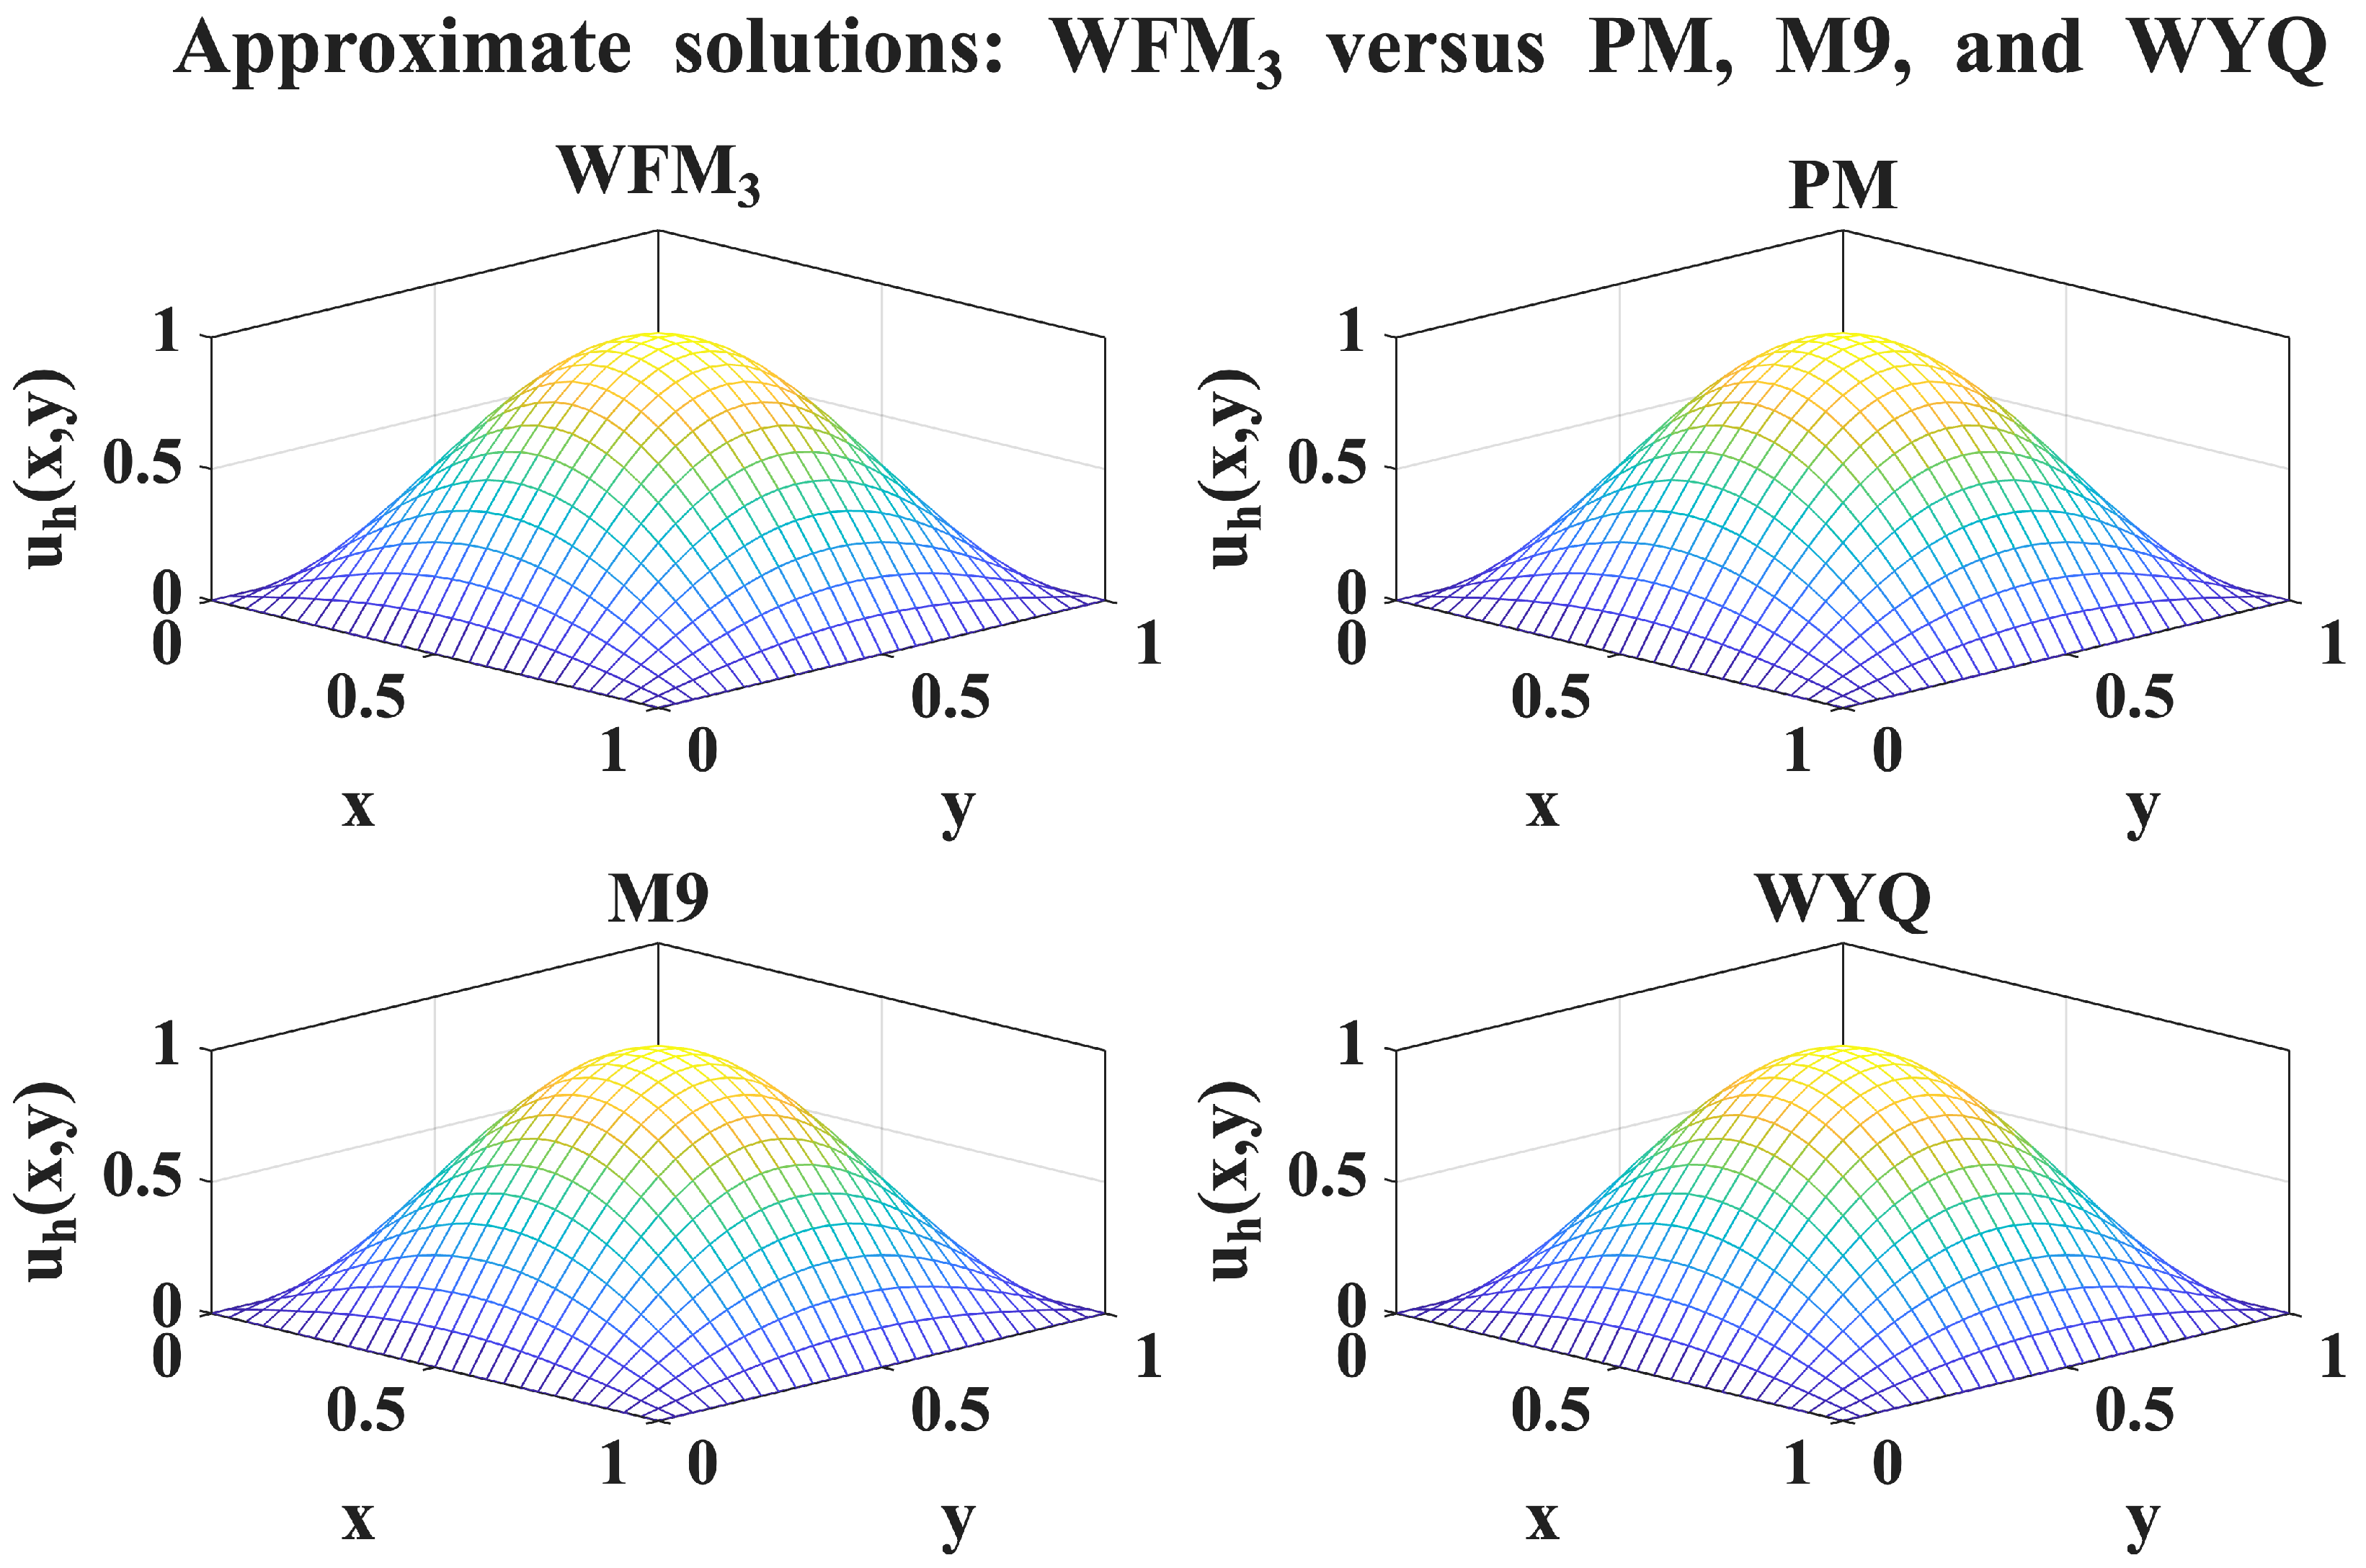
The Fredholm integral equation provides a relevant test because its quadrature discretization leads to dense nonlinear algebraic systems. In this setting, the proposed WFM methods maintain high accuracy and competitive CPU times, showing that the family is not restricted to artificial low-dimensional examples. The semilinear elliptic Dirichlet problem gives an additional and more demanding validation, since the finite-difference discretization generates structured nonlinear systems whose size increases with mesh refinement. The results obtained for both coarse and finer meshes show that the proposed methods reproduce the manufactured solution with small spatial errors and robust residual reduction.
Overall, the proposed family combines three desirable properties: optimal eighth-order convergence, computational efficiency, and flexibility through admissible weight functions. Future work may focus on semilocal convergence, the adaptive selection of weight functions, implementation for sparse and large-scale systems, and the extension of the proposed framework to problems with singular or nearly singular Jacobians, as well as to nonlinear systems arising from time-dependent partial differential equations.




 ,