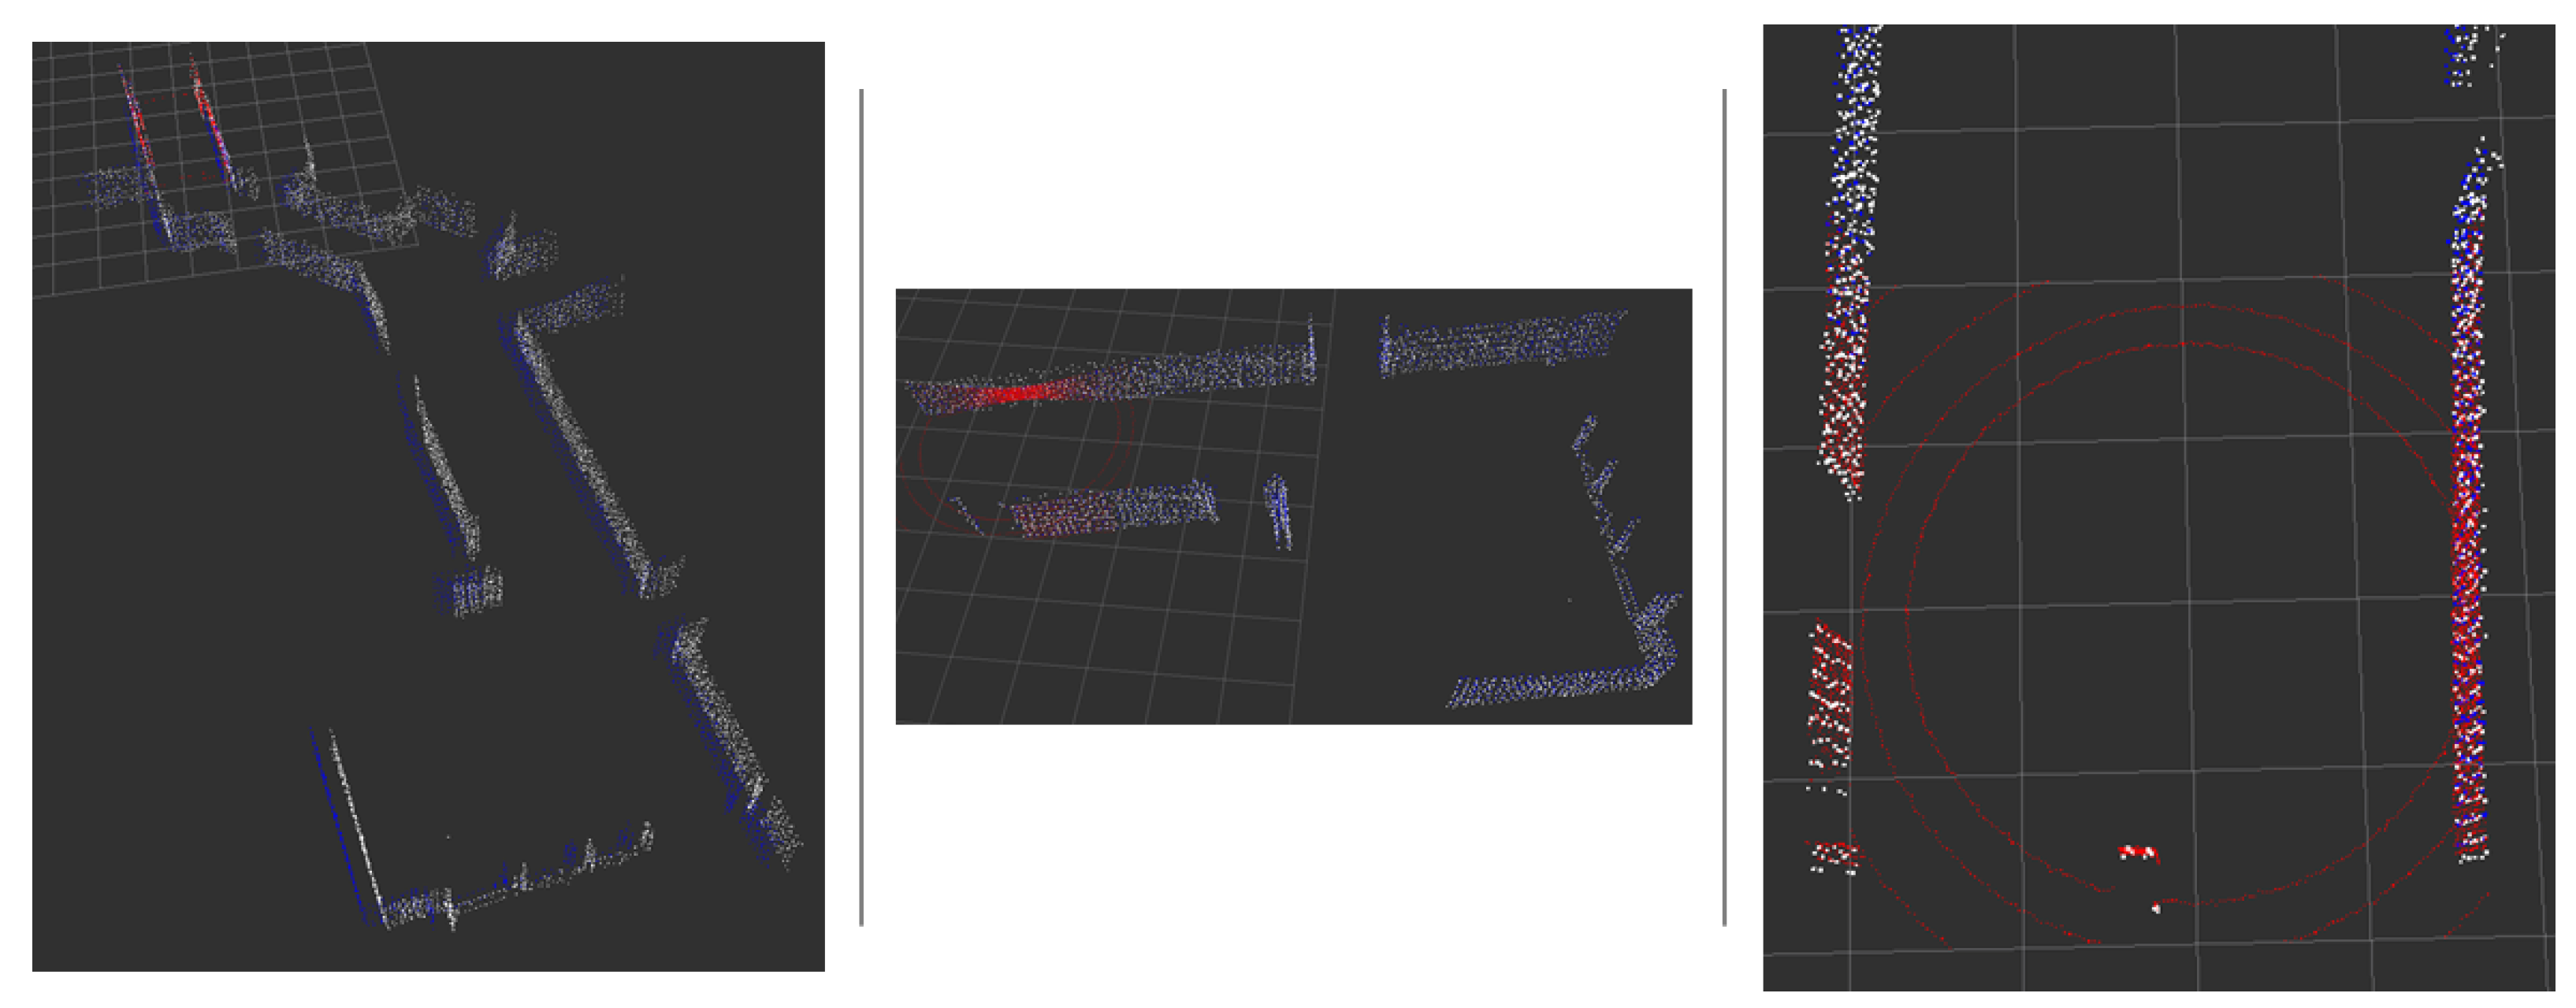
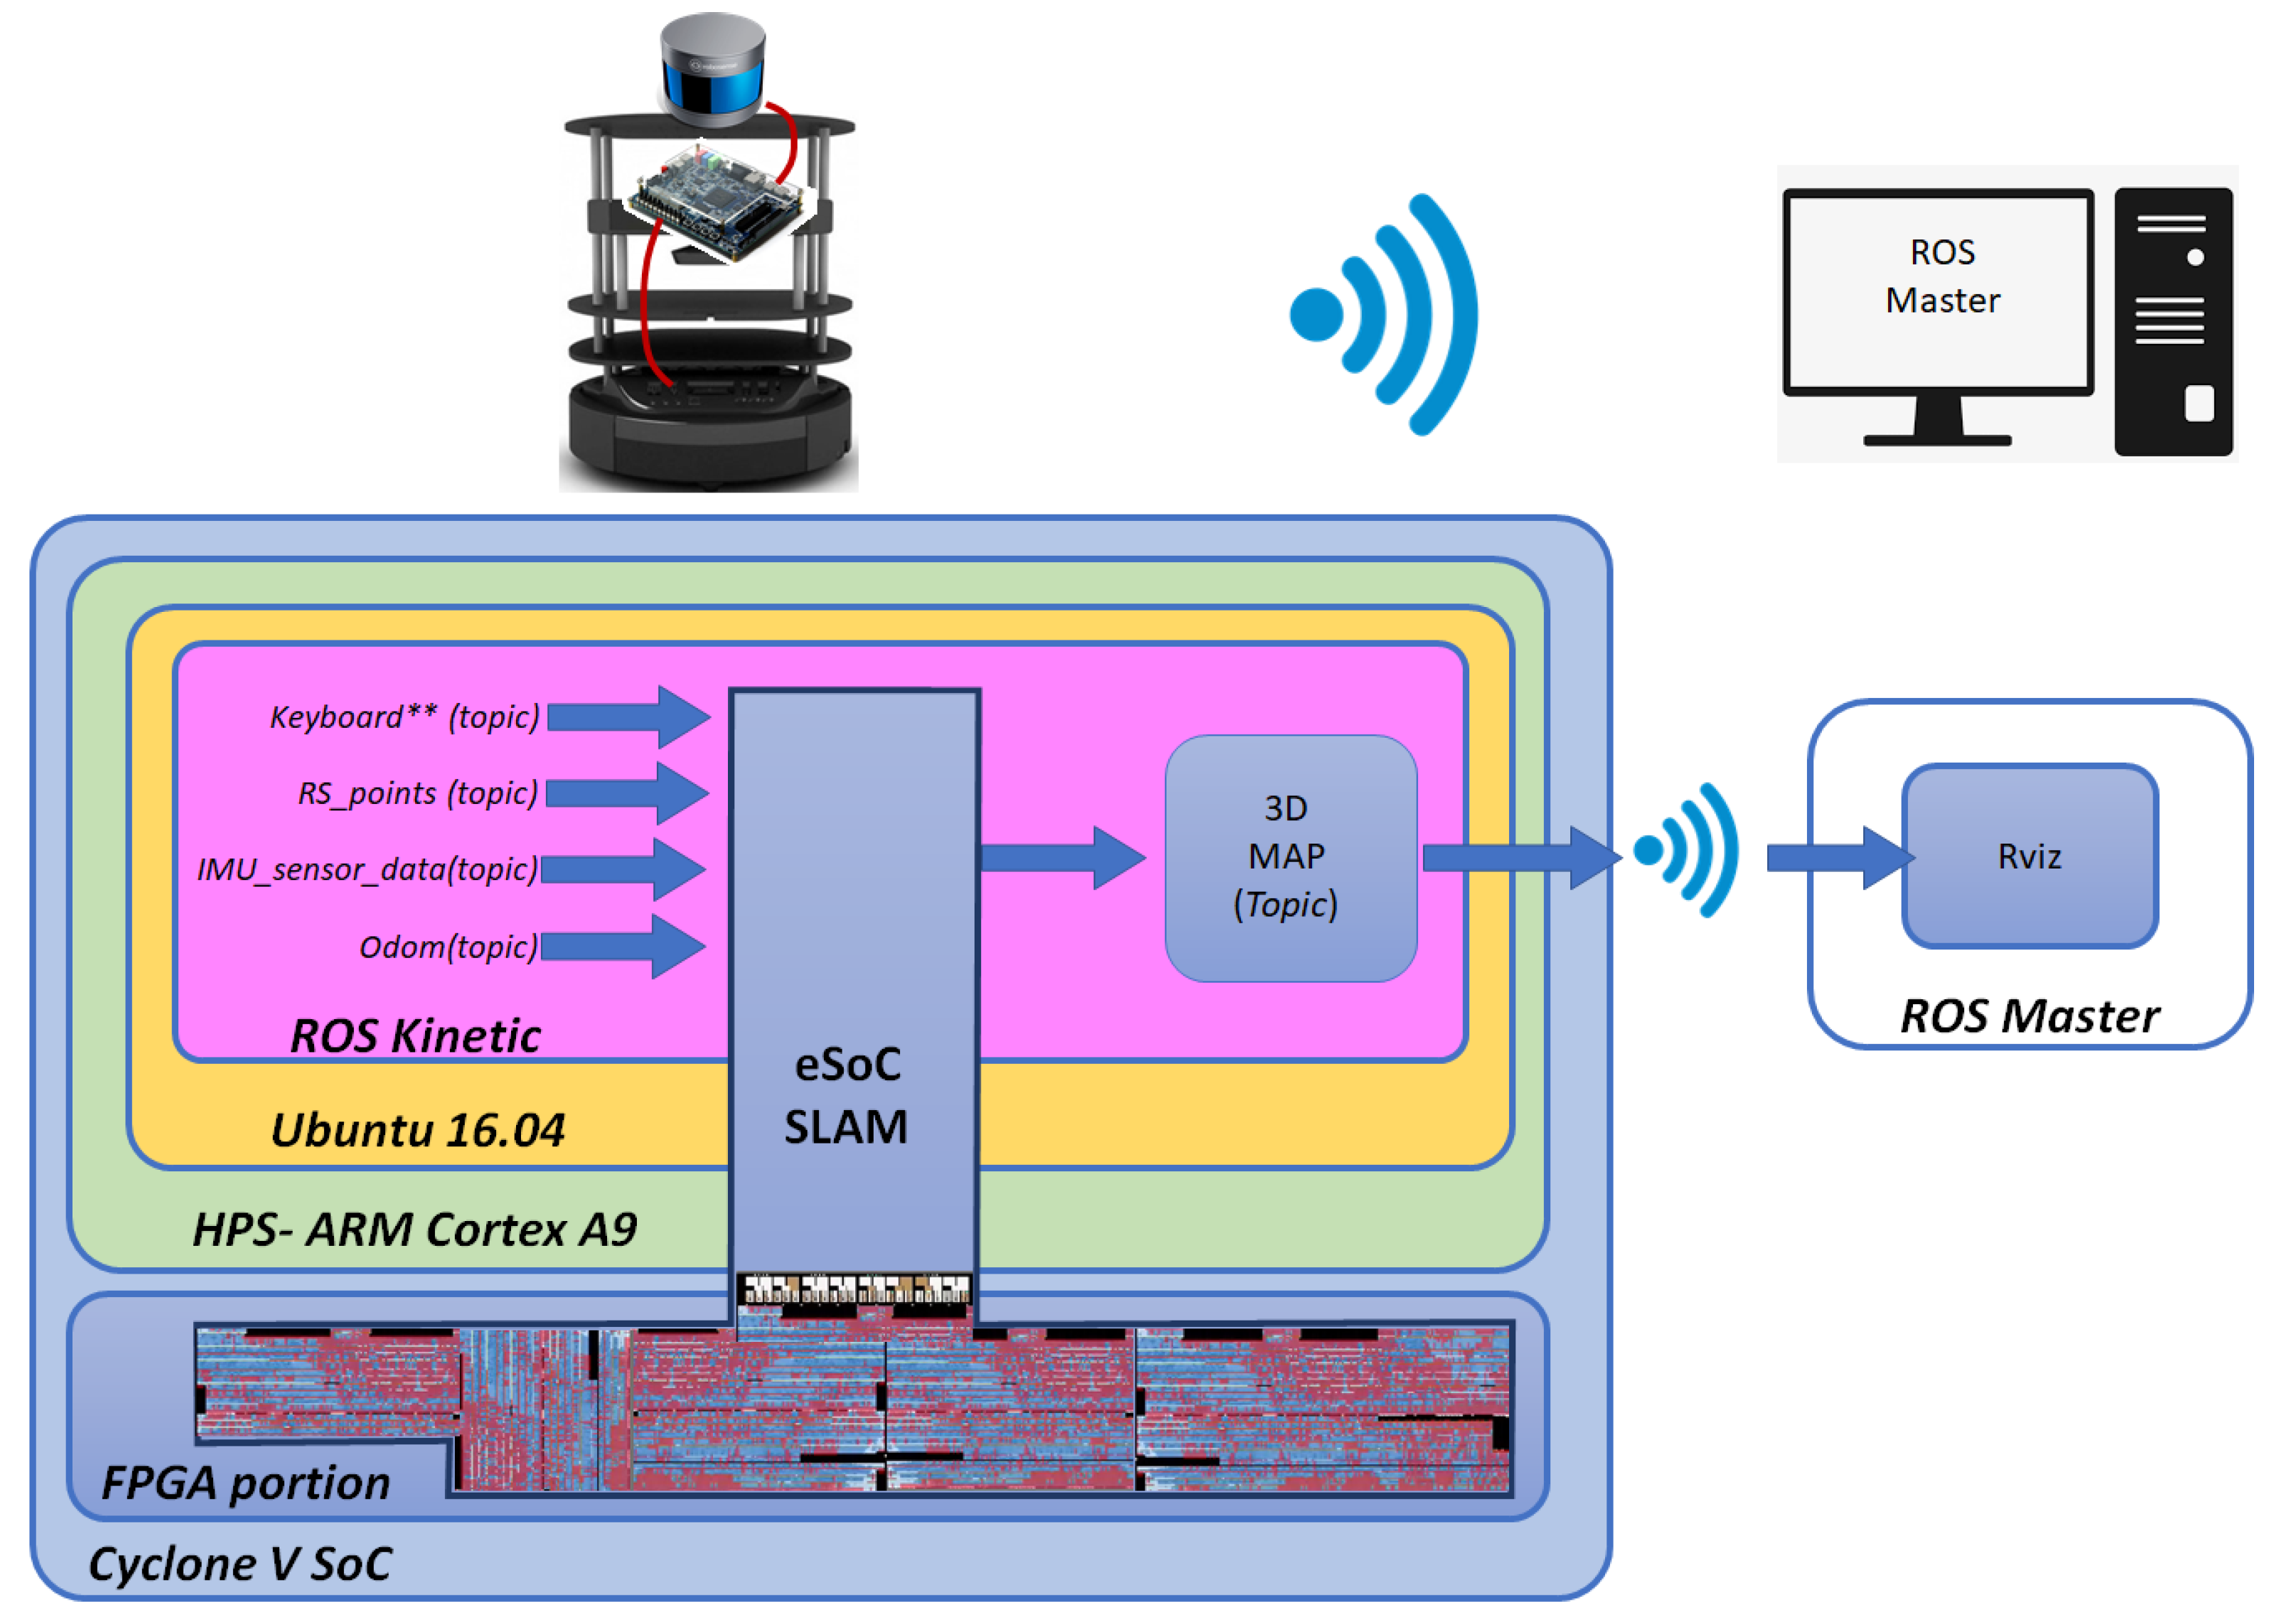
Embbedded System-on-Chip 3D Localization and Mapping—eSoC-SLAM
 , , , and
Abstract
Share and Cite
Gerlein, E.A.; Díaz-Guevara, G.; Carrillo, H.; Parra, C.; Gonzalez, E. Embbedded System-on-Chip 3D Localization and Mapping—eSoC-SLAM. Electronics 2021, 10, 1378. https://doi.org/10.3390/electronics10121378
Gerlein EA, Díaz-Guevara G, Carrillo H, Parra C, Gonzalez E. Embbedded System-on-Chip 3D Localization and Mapping—eSoC-SLAM. Electronics. 2021; 10(12):1378. https://doi.org/10.3390/electronics10121378
Chicago/Turabian StyleGerlein, Eduardo A., Gabriel Díaz-Guevara, Henry Carrillo, Carlos Parra, and Enrique Gonzalez. 2021. "Embbedded System-on-Chip 3D Localization and Mapping—eSoC-SLAM" Electronics 10, no. 12: 1378. https://doi.org/10.3390/electronics10121378
APA StyleGerlein, E. A., Díaz-Guevara, G., Carrillo, H., Parra, C., & Gonzalez, E. (2021). Embbedded System-on-Chip 3D Localization and Mapping—eSoC-SLAM. Electronics, 10(12), 1378. https://doi.org/10.3390/electronics10121378