MAAT: A Marine-Aware Adaptive Tracker for Robust and Real-Time Multi-Object Tracking in Maritime Environments




Abstract
1. Introduction
- (1)
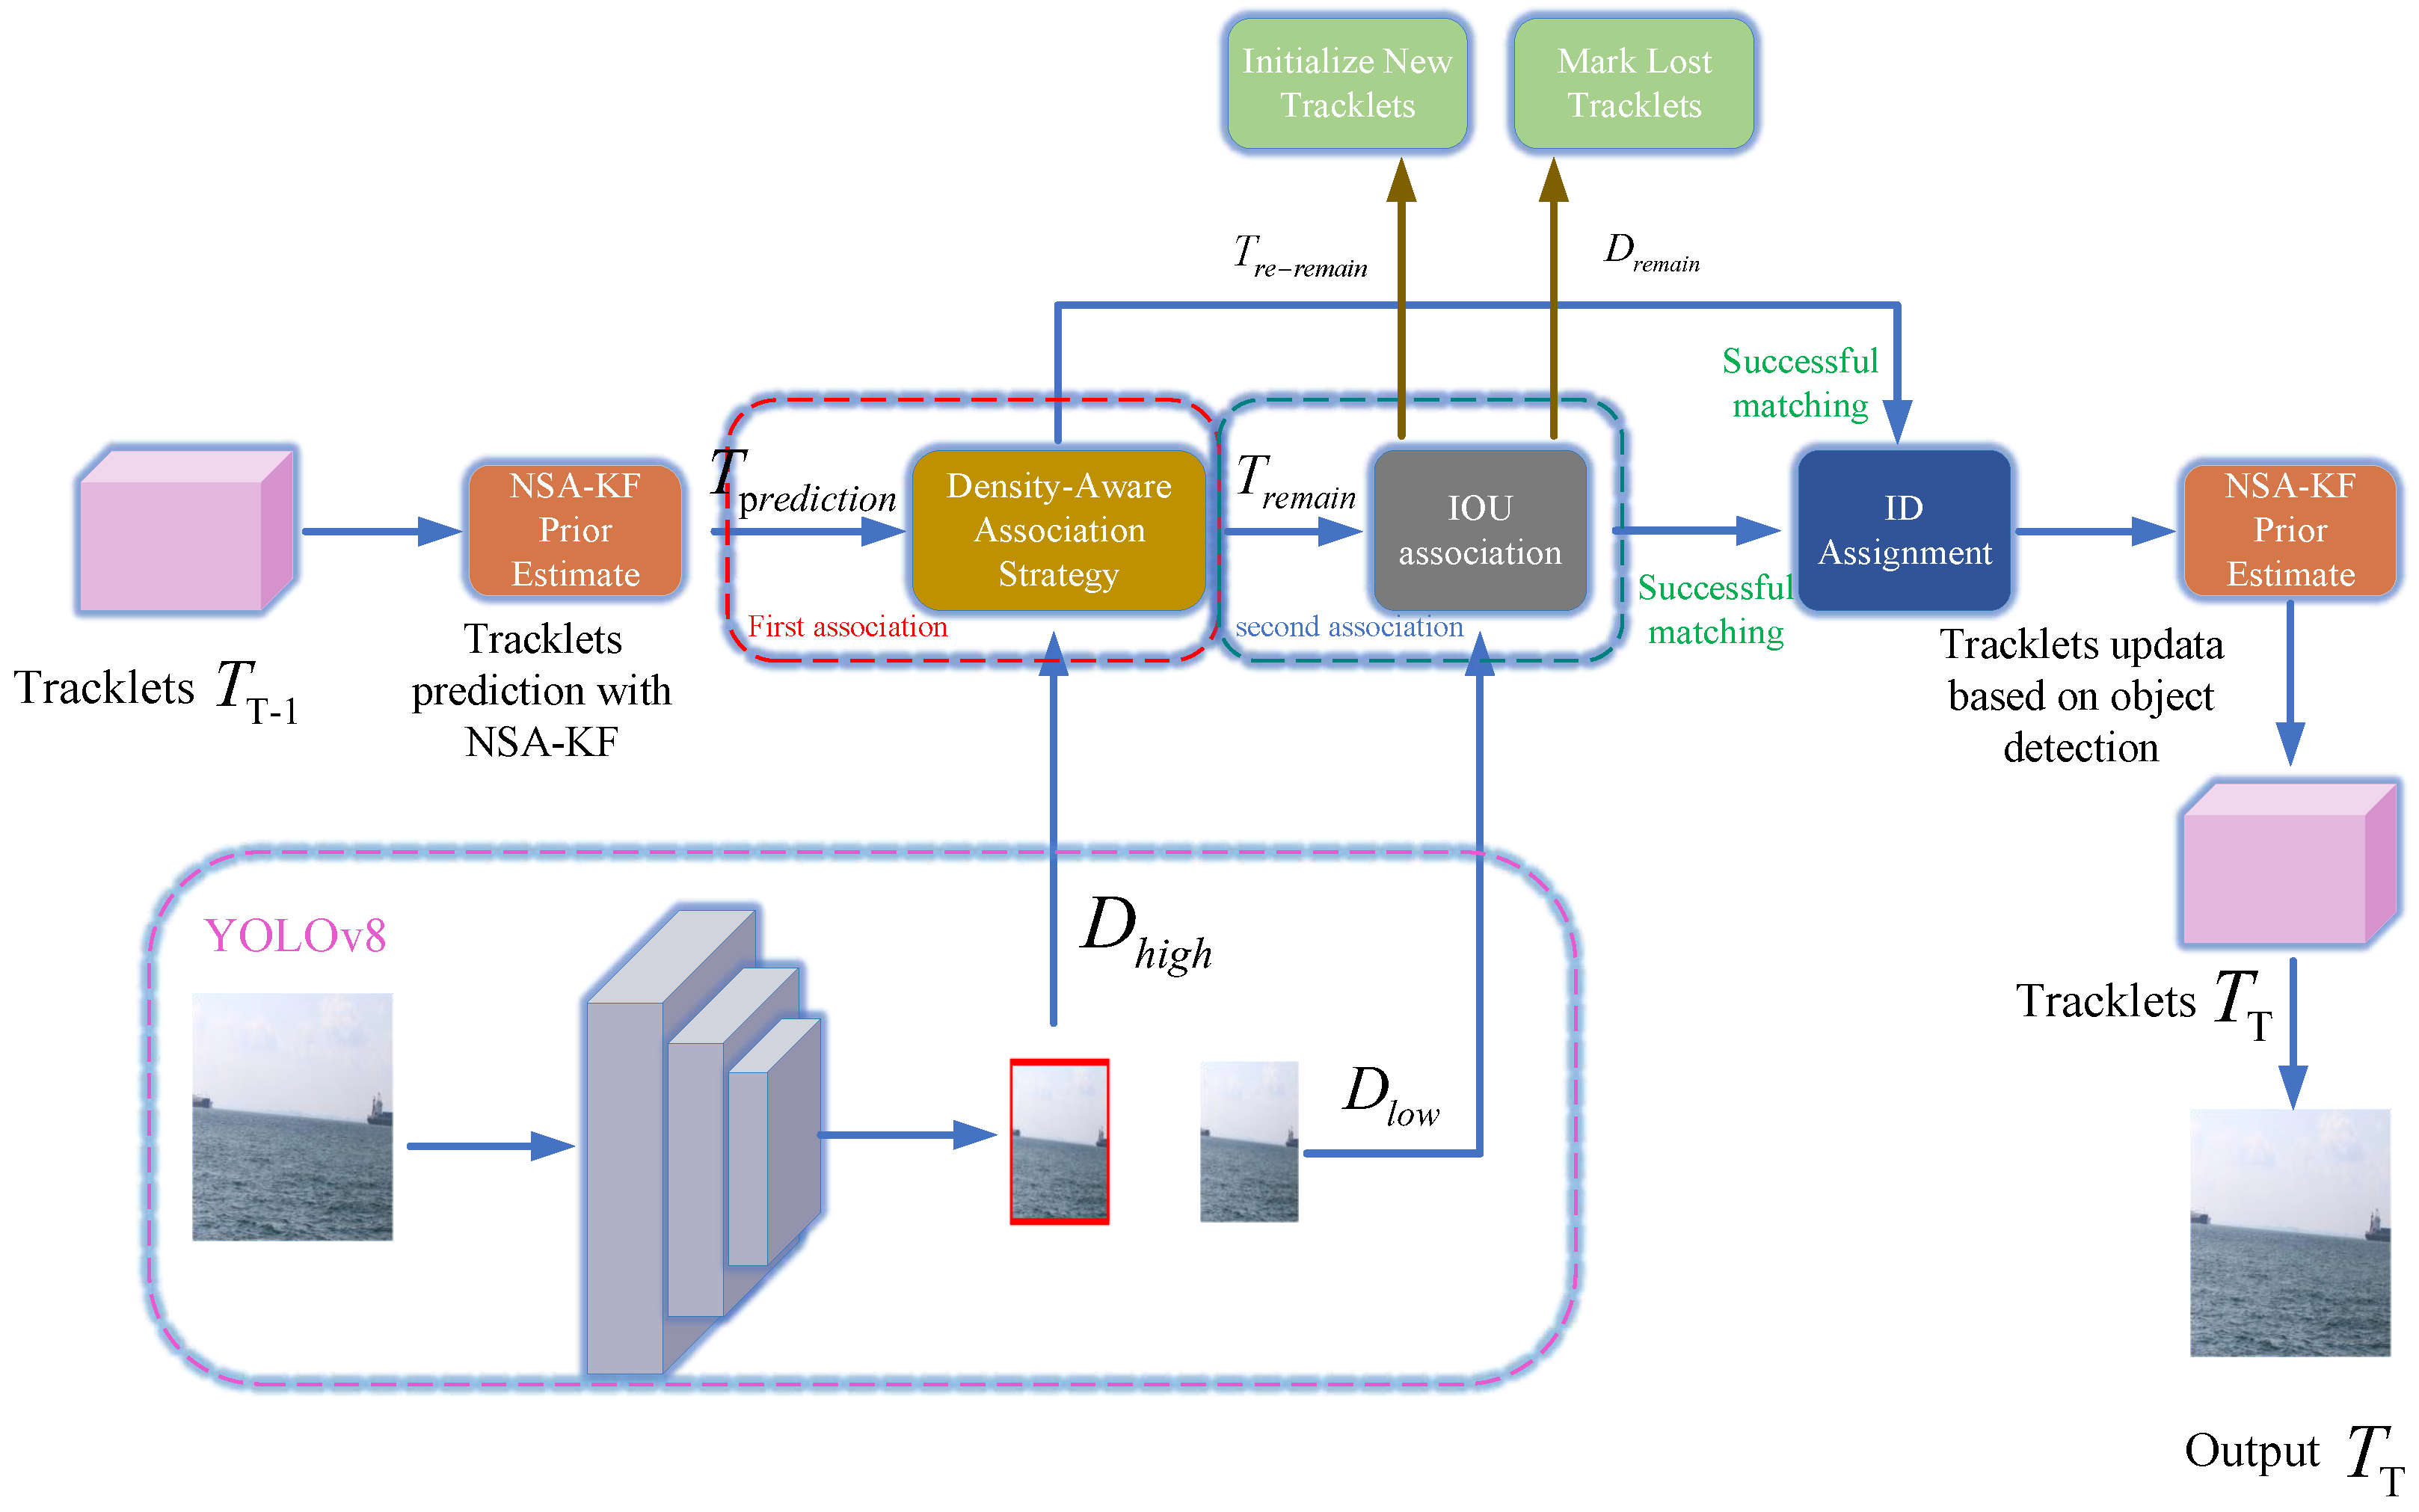
- To address the degradation of state estimation caused by nonlinear motion under platform jitter, an adaptive Kalman filtering mechanism is introduced to dynamically adjust the contribution of observations during the update stage, thereby improving the robustness and reliability of motion prediction in complex maritime environments.
- (2)
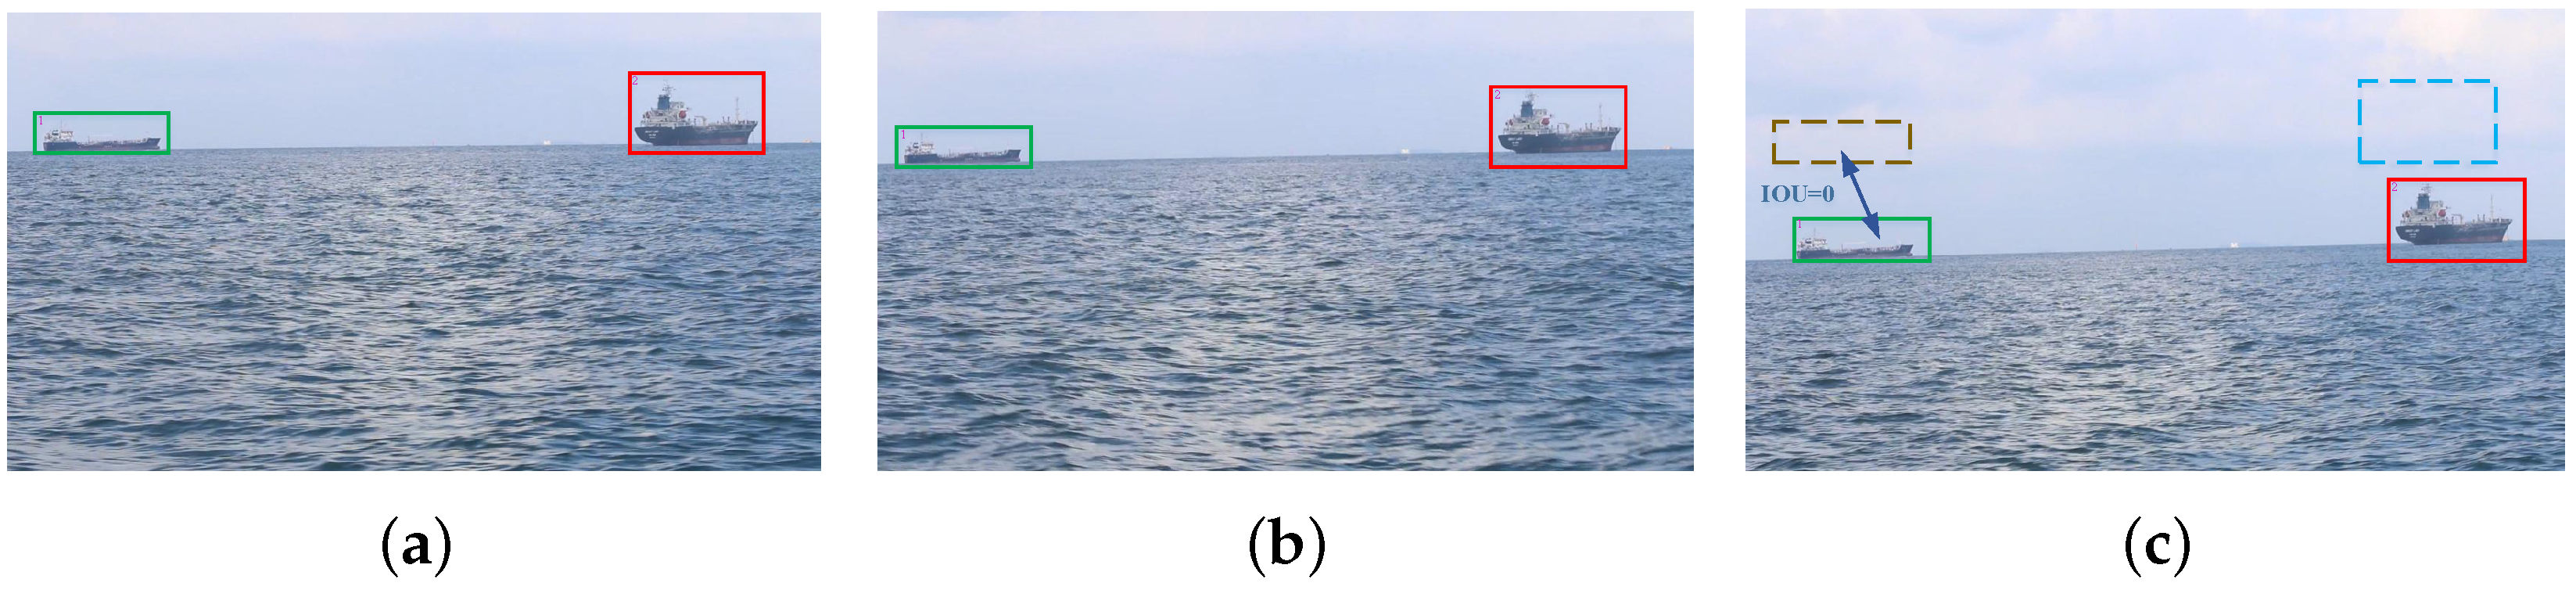
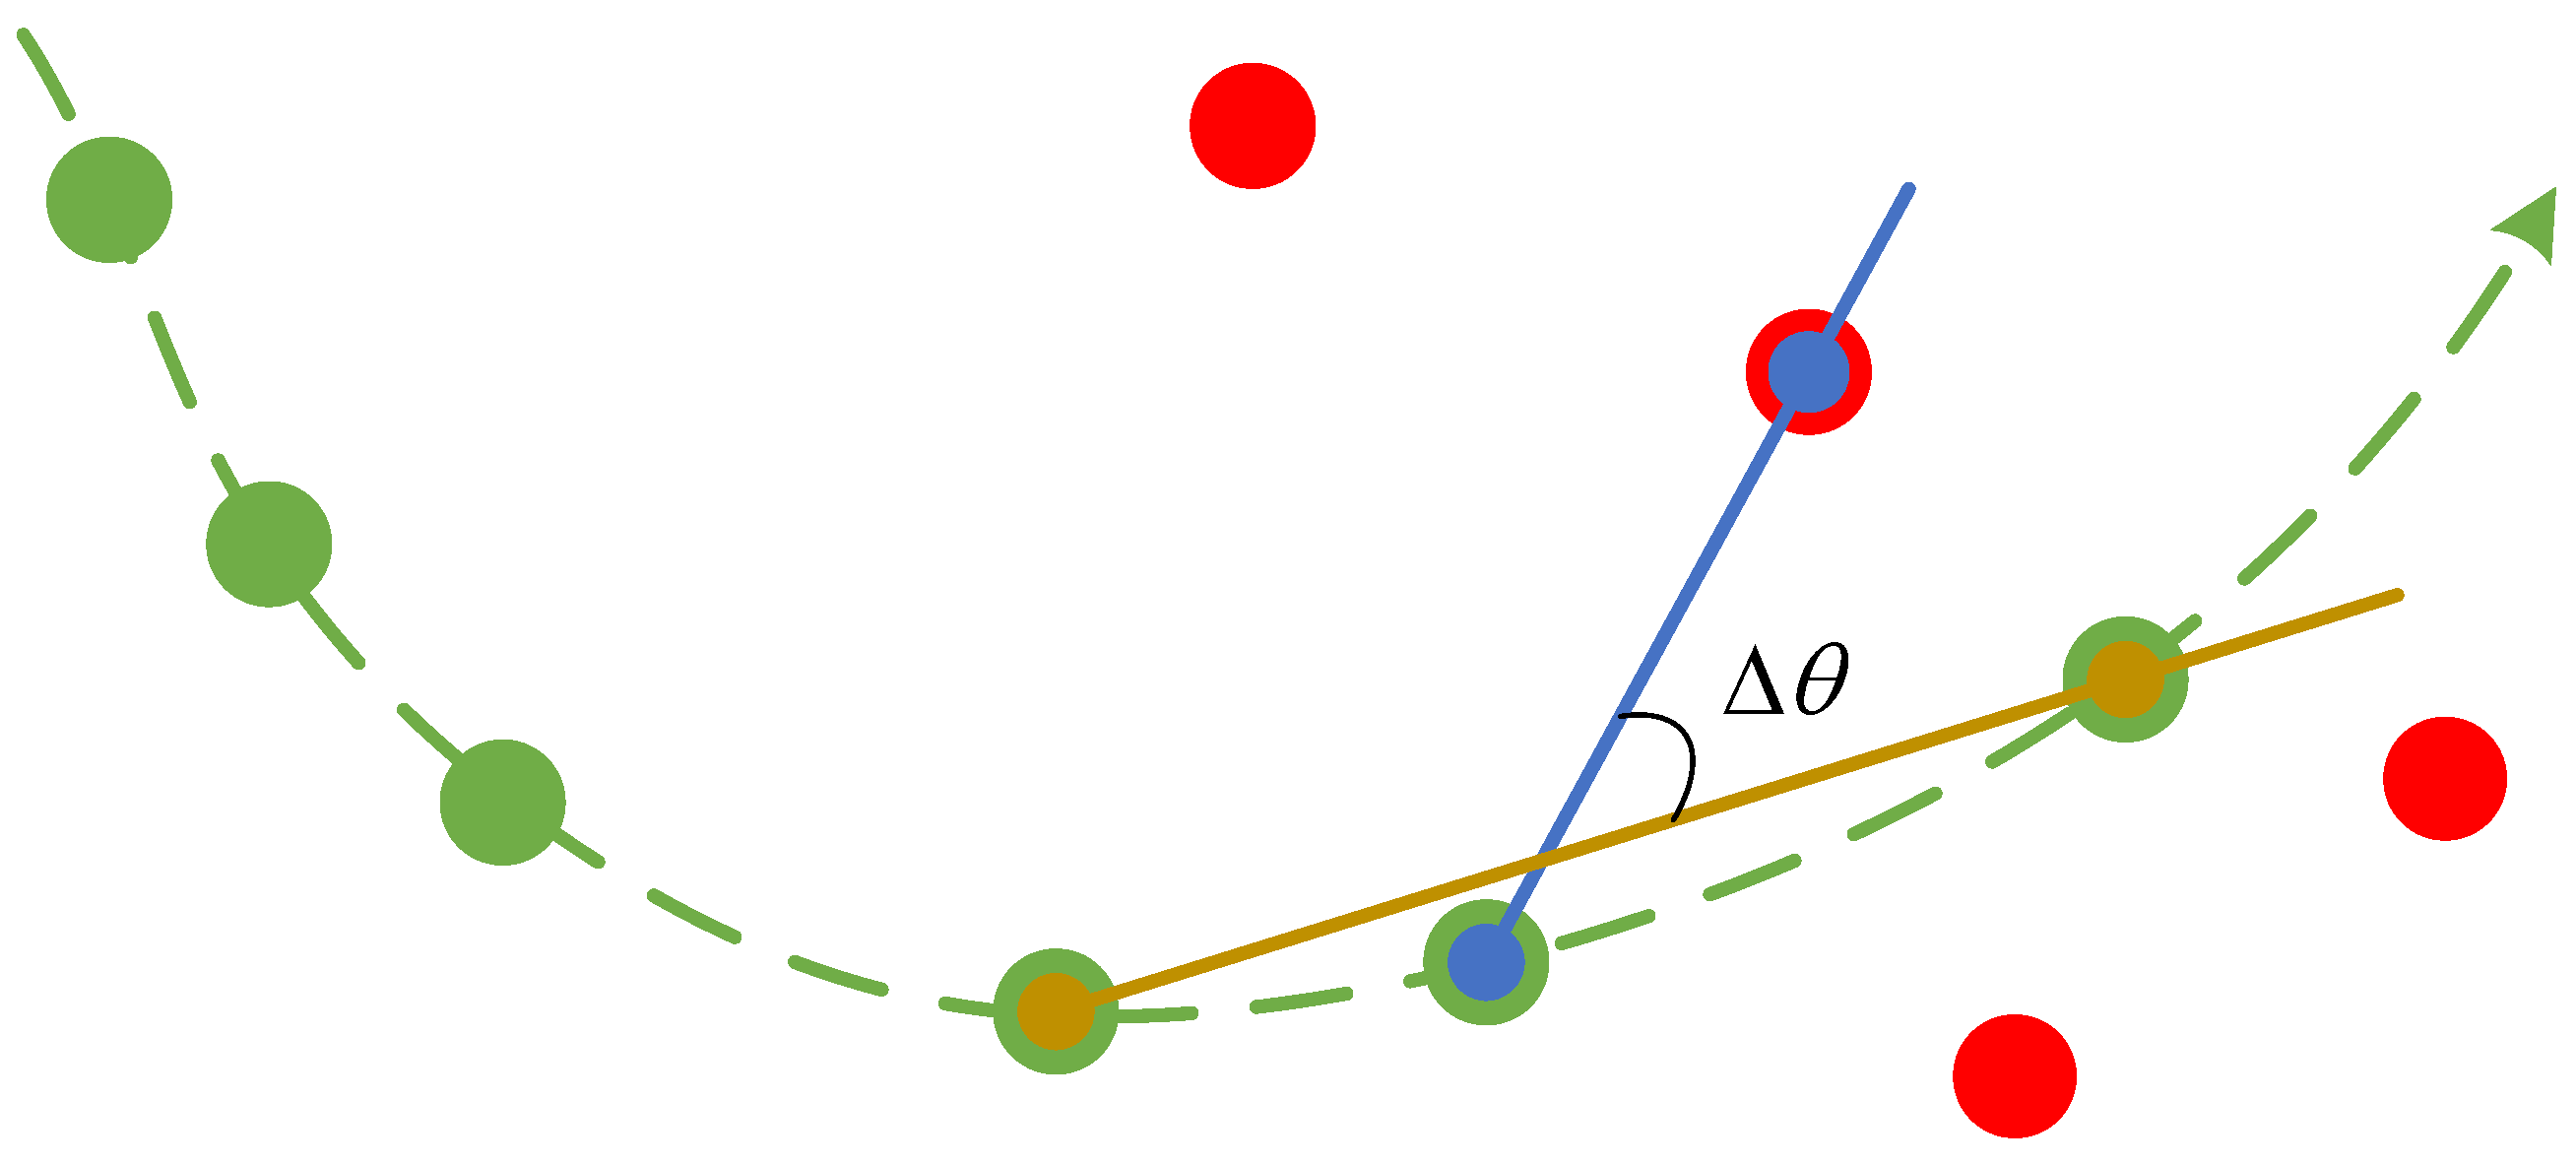
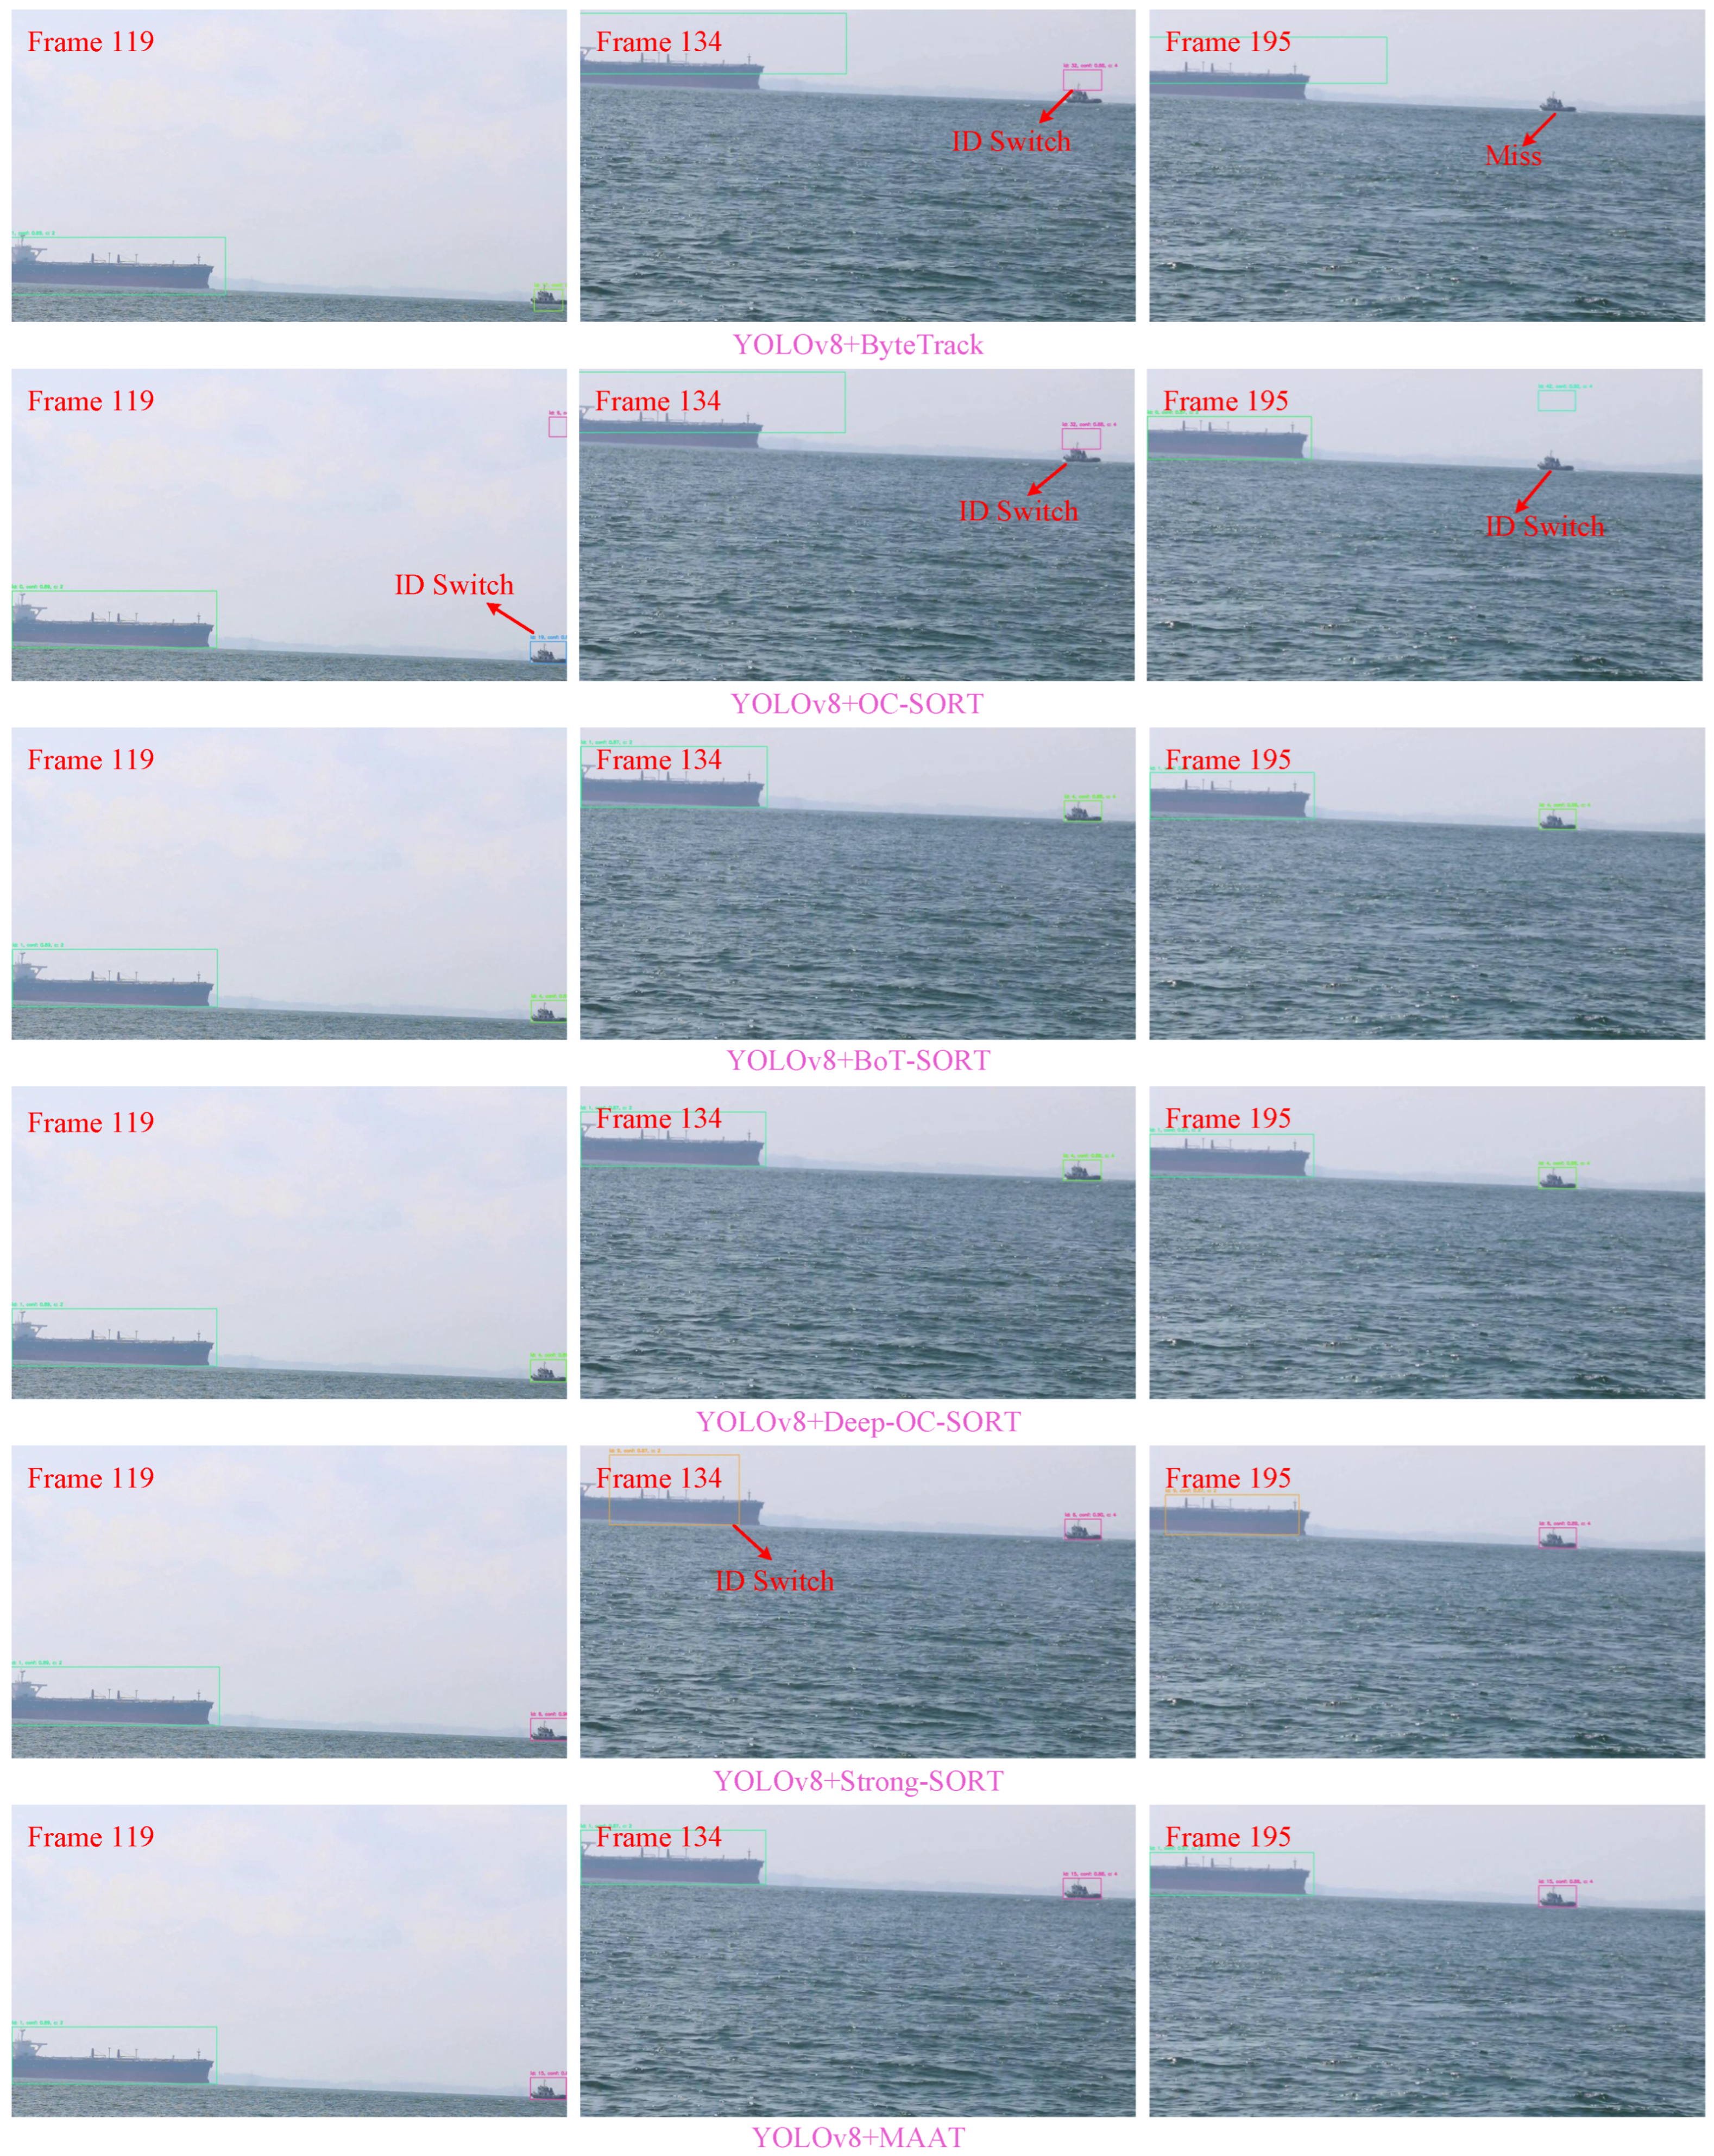
- To address the failure of conventional IoU-based association caused by severe platform-induced jitter, a density-aware association strategy is proposed. By adaptively adjusting the composition of the cost matrix, the proposed method enhances association robustness and effectively reduces identity switches under unstable observations.
2. Related Work
2.1. Tracking by Detection
2.2. Tracking by Transformer
2.3. Motion Models
2.4. Data Association
3. Method
3.1. ByteTrack
3.2. Marine-Aware Adaptive Track
| Algorithm 1 Pseudo-code of the MAAT tracking algorithm |
|
3.2.1. Noise-Scale Adaptive Kalman Filter
3.2.2. Density-Aware Association Strategy
| Algorithm 2 Density-Aware Association Strategy (DAAS) |
|
3.3. Detector
4. Experiment
4.1. Datasets and Metrics
4.2. Implementation Details and Parameter Settings
4.3. Quantitative Experiment Analysis
4.3.1. Comparative Experiments
4.3.2. Ablation Experiments
5. Conclusions
Author Contributions
Funding
Data Availability Statement
Conflicts of Interest
| 1 | https://github.com/tilemmpon/Singapore-Maritime-Dataset-Frames-Ground-Truth-Generation-and-Statistics (accessed on 11 April 2026) |
References
- Li, J.; Zhao, L.; Zheng, Z.; Yong, T. Review of multi-object tracking based on deep learning. In 2022 Asia Conference on Algorithms, Computing and Machine Learning (CACML); IEEE: Piscataway, NJ, USA, 2022; pp. 719–725. [Google Scholar]
- Ma, S.; Zhao, Z.; Hou, Z.; Zhang, L.; Yang, X.; Pu, L. Correlation filters based on multi-expert and game theory for visual object tracking. IEEE Trans. Instrum. Meas. 2022, 71, 2510814. [Google Scholar] [CrossRef] [Scilit]
- Sun, S.; Yin, Y.; Wang, X.; Xu, D. Robust visual detection and tracking strategies for autonomous aerial refueling of UAVs. IEEE Trans. Instrum. Meas. 2019, 68, 4640–4652. [Google Scholar] [CrossRef] [Scilit]
- Luo, W.; Xing, J.; Milan, A.; Zhang, X.; Liu, W.; Kim, T.K. Multiple object tracking: A literature review. Artif. Intell. 2021, 293, 103448. [Google Scholar] [CrossRef] [Scilit]
- Bewley, A.; Ge, Z.; Ott, L.; Ramos, F.; Upcroft, B. Simple online and realtime tracking. In IEEE International Conference on Image Processing; IEEE: Piscataway, NJ, USA, 2016; pp. 3464–3468. [Google Scholar]
- Wojke, N.; Bewley, A.; Paulus, D. Simple online and realtime tracking with a deep association metric. In IEEE International Conference on Image Processing; IEEE: Piscataway, NJ, USA, 2017; pp. 3645–3649. [Google Scholar]
- Zhang, Y.; Wang, C.; Wang, X.; Zeng, W.; Liu, W. FairMOT: On the fairness of detection and re-identification in multiple object tracking. Int. J. Comput. Vis. 2021, 129, 3069–3087. [Google Scholar] [CrossRef] [Scilit]
- Zhang, H.; Xing, W.; Yang, Y.; Li, Y.; Yuan, D. SiamST: Siamese network with spatio-temporal awareness for object tracking. Inf. Sci. 2023, 634, 122–139. [Google Scholar] [CrossRef] [Scilit]
- Zhang, Y.; Sun, P.; Jiang, Y.; Yu, D.; Weng, F.; Yuan, Z.; Luo, P.; Liu, W.; Wang, X. ByteTrack: Multi-object tracking by associating every detection box. In Computer Vision—ECCV 2022; European Conference on Computer Vision; Springer: Cham, Switzerland, 2022; pp. 1–21. [Google Scholar]
- Li, G.; Ouyang, D.; Chen, X.; Chu, W.; Lu, B.; Zhang, C.; Tang, X.; Guo, G. Pedestrian tracking based on receptive field improvement: A one-shot multiobject tracking approach based on vision sensors. IEEE Sens. J. 2023, 23, 18893–18907. [Google Scholar] [CrossRef] [Scilit]
- Patel, A.S.; Vyas, R.; Vyas, O.; Ojha, M.; Tiwari, V. Motion-compensated online object tracking for activity detection and crowd behavior analysis. Vis. Comput. 2023, 39, 2127–2147. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Che, J.; He, Y.; Wu, J. Pedestrian multiple-object tracking based on FairMOT and circle loss. Sci. Rep. 2023, 13, 4525. [Google Scholar] [CrossRef] [Scilit]
- Wang, H.; Xu, Y.; Wang, Z.; Cai, Y.; Chen, L.; Li, Y. CenterNet-Auto: A multi-object visual detection algorithm for autonomous driving scenes based on improved CenterNet. IEEE Trans. Emerg. Top. Comput. Intell. 2023, 7, 742–752. [Google Scholar] [CrossRef] [Scilit]
- Liu, J.; Ding, G.; Xia, Y.; Sun, J.; Huang, T.; Xie, L.; Zhu, B. Which framework is suitable for online 3D multi-object tracking for autonomous driving with automotive 4D imaging radar? In IEEE Intelligent Vehicles Symposium; IEEE: Piscataway, NJ, USA, 2024; pp. 1258–1265. [Google Scholar]
- Chen, L.; Ai, H.; Zhuang, Z.; Shang, C. Real-time multiple people tracking with deeply learned candidate selection and person re-identification. arXiv 2018, arXiv:1809.04427. [Google Scholar] [CrossRef] [Scilit]
- Voigtlaender, P.; Krause, M.; Osep, A.; Luiten, J.; Sekar, B.; Geiger, A.; Leibe, B. MOTS: Multi-object tracking and segmentation. In Proceedings of the IEEE/CVF Conference on Computer Vision and Pattern Recognition; IEEE: Piscataway, NJ, USA, 2019; pp. 7942–7951. [Google Scholar]
- Yin, L.; Zhang, R.; Gu, H.; Guan, N. Research on situation cognition approach of USV under complex ocean conditions. Int. J. Veh. Des. 2023, 91, 263–287. [Google Scholar] [CrossRef] [Scilit]
- Dong, K.; Liu, T.; Zheng, Y.; Shi, Z.; Du, H.; Wang, X. Visual detection algorithm for enhanced environmental perception of unmanned surface vehicles in complex marine environments. J. Intell. Robot. Syst. 2024, 110, 1. [Google Scholar] [CrossRef] [Scilit]
- Wang, Y.; Liu, W.; Liu, J.; Sun, C. Cooperative USV–UAV marine search and rescue with visual navigation and reinforcement learning-based control. ISA Trans. 2023, 137, 222–235. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Abd Alhattab, Y.; Abidin, Z.B.Z.; Faizabadi, A.R.; Zaki, H.; Ibrahim, A.I. Integration of stereo vision and MOOS-IvP for enhanced obstacle detection and navigation in unmanned surface vehicles. IEEE Access 2023, 11, 128932–128956. [Google Scholar] [CrossRef] [Scilit]
- Huang, K.; Chong, W.; Yang, H.; Lertniphonphan, K.; Xie, J.; Chen, F. ReIDTracker_Sea: Multi-object tracking in maritime computer vision. In IEEE/CVF Winter Conference on Applications of Computer Vision Workshops; IEEE: Piscataway, NJ, USA, 2024; pp. 813–820. [Google Scholar]
- Lin, J.; Diekmann, P.; Framing, C.E.; Zweigel, R.; Abel, D. Maritime environment perception based on deep learning. IEEE Trans. Intell. Transp. Syst. 2022, 23, 15487–15497. [Google Scholar] [CrossRef] [Scilit]
- Han, J.; Kim, S.Y.; Kim, J. Enhanced target ship tracking with geometric parameter estimation for unmanned surface vehicles. IEEE Access 2021, 9, 39864–39872. [Google Scholar] [CrossRef] [Scilit]
- Redmon, J.; Farhadi, A. YOLOv3: An incremental improvement. arXiv 2018, arXiv:1804.02767. [Google Scholar] [CrossRef] [Scilit]
- Bochkovskiy, A.; Wang, C.Y.; Liao, H.Y.M. YOLOv4: Optimal speed and accuracy of object detection. arXiv 2020, arXiv:2004.10934. [Google Scholar] [CrossRef] [Scilit]
- Ren, S.; He, K.; Girshick, R.; Sun, J. Faster R-CNN: Towards real-time object detection with region proposal networks. In Advances in Neural Information Processing Systems; Curran Associates, Inc.: Red Hook, NY, USA, 2015; Volume 28. [Google Scholar]
- Lin, T.Y.; Goyal, P.; Girshick, R.; He, K.; Dollár, P. Focal loss for dense object detection. In Proceedings of the IEEE International Conference on Computer Vision; IEEE: Piscataway, NJ, USA, 2017; pp. 2980–2988. [Google Scholar]
- Liu, W.; Anguelov, D.; Erhan, D.; Szegedy, C.; Reed, S.; Fu, C.Y.; Berg, A. SSD: Single shot multibox detector. In Computer Vision—ECCV 2016; European Conference on Computer Vision; Springer: Cham, Switzerland, 2016; pp. 21–37. [Google Scholar]
- Duan, K.; Bai, S.; Xie, L.; Qi, H.; Huang, Q.; Tian, Q. CenterNet: Keypoint triplets for object detection. In Proceedings of the IEEE/CVF International Conference on Computer Vision; IEEE: Piscataway, NJ, USA, 2019; pp. 6569–6578. [Google Scholar]
- Kuhn, H.W. The Hungarian method for the assignment problem. Nav. Res. Logist. Q. 1955, 2, 83–97. [Google Scholar] [CrossRef] [Scilit]
- Huang, G.; Zhou, K.; Trawny, N.; Roumeliotis, S. A bank of maximum a posteriori estimators for target tracking. IEEE Trans. Robot. 2015, 31, 85–103. [Google Scholar] [CrossRef] [Scilit]
- Sun, P.; Cao, J.; Jiang, Y.; Zhang, R.; Xie, E.; Yuan, Z.; Wang, C.; Luo, P. TransTrack: Multiple object tracking with transformer. arXiv 2020, arXiv:2012.15460. [Google Scholar]
- Meinhardt, T.; Kirillov, A.; Leal-Taixe, L.; Feichtenhofer, C. TrackFormer: Multi-object tracking with transformers. In Proceedings of the IEEE/CVF Conference on Computer Vision and Pattern Recognition; IEEE: Piscataway, NJ, USA, 2022; pp. 8844–8854. [Google Scholar]
- Zeng, F.; Dong, B.; Zhang, Y.; Wang, T.; Zhang, X.; Wei, Y. MOTR: End-to-end multiple-object tracking with transformer. In Computer Vision—ECCV 2022; European Conference on Computer Vision; Springer: Cham, Switzerland, 2022; pp. 659–675. [Google Scholar]
- Carion, N.; Massa, F.; Synnaeve, G.; Usunier, N.; Kirillov, A.; Zagoruyko, S. End-to-end object detection with transformers. In Computer Vision—ECCV 2020; European Conference on Computer Vision; Springer: Cham, Switzerland, 2020; pp. 213–229. [Google Scholar]
- Yang, Y. Robust Bayesian estimation. Bull. Géodésique 1991, 65, 145–150. [Google Scholar]
- Lv, G.H.; Qin, P.L.; Miao, Q.G.; Liu, M.M.; Jiao, P.F. Research of extended Kalman filter based on multi-innovation theory. J. Chin. Comput. Syst. 2016, 37, 576–580. [Google Scholar]
- Julier, S.J.; Uhlmann, J.K. Unscented filtering and nonlinear estimation. Proc. IEEE 2004, 92, 401–422. [Google Scholar] [CrossRef] [Scilit]
- Aharon, N.; Orfaig, R.; Bobrovsky, B.Z. BoT-SORT: Robust associations multi-pedestrian tracking. arXiv 2022, arXiv:2206.14651. [Google Scholar]
- Do, T.T.; Che, H.Q.; Truong, C.V. Fast camera motion compensation based Kalman filter and cascade association for multi-object tracking. In Recent Challenges in Intelligent Information and Database Systems; Asian Conference on Intelligent Information and Database Systems; Springer: Cham, Switzerland, 2023; pp. 3–15. [Google Scholar]
- Cao, J.; Pang, J.; Weng, X.; Khirodkar, R.; Kitani, K. Observation-centric SORT: Rethinking SORT for robust multi-object tracking. In Proceedings of the IEEE/CVF Conference on Computer Vision and Pattern Recognition; IEEE: Piscataway, NJ, USA, 2023; pp. 9686–9696. [Google Scholar]
- Wang, C.Y.; Yeh, I.H.; Mark Liao, H.Y. YOLOv9: Learning what you want to learn using programmable gradient information. In Computer Vision—ECCV 2024; European Conference on Computer Vision; Springer: Cham, Switzerland, 2024; pp. 1–21. [Google Scholar]
- Wang, A.; Chen, H.; Liu, L.; Chen, K.; Lin, Z.; Han, J.; Ding, G. YOLOv10: Real-time end-to-end object detection. In Advances in Neural Information Processing Systems; Curran Associates, Inc.: Red Hook, NY, USA, 2024; Volume 37, pp. 107984–108011. [Google Scholar]
- Tian, Y.; Ye, Q.; Doermann, D. YOLOv12: Attention-centric real-time object detectors. arXiv 2025, arXiv:2502.12524. [Google Scholar]
- Prasad, D.K.; Rajan, D.; Rachmawati, L.; Rajabally, E.; Quek, C. Video processing from electro-optical sensors for object detection and tracking in a maritime environment: A survey. IEEE Trans. Intell. Transp. Syst. 2017, 18, 1993–2016. [Google Scholar] [CrossRef] [Scilit]
- Fischler, M.A.; Bolles, R.C. Random sample consensus: A paradigm for model fitting with applications to image analysis and automated cartography. Commun. ACM 1981, 24, 381–395. [Google Scholar] [CrossRef] [Scilit]
- Bernardin, K.; Stiefelhagen, R. Evaluating multiple object tracking performance: The clear mot metrics. EURASIP J. Image Video Process. 2008, 2008, 246309. [Google Scholar] [CrossRef] [Scilit]
- Maggiolino, G.; Ahmad, A.; Cao, J.; Kitani, K. Deep oc-sort: Multi-pedestrian tracking by adaptive re-identification. In 2023 IEEE International Conference on Image Processing (ICIP); IEEE: Piscataway, NJ, USA, 2023; pp. 3025–3029. [Google Scholar]
- Du, Y.; Zhao, Z.; Song, Y.; Zhao, Y.; Su, F.; Gong, T.; Meng, H. Strongsort: Make deepsort great again. IEEE Trans. Multimed. 2023, 25, 8725–8737. [Google Scholar] [CrossRef] [Scilit]



| Method | P | R | mAP@0.5 | mAP@0.5:0.95 | Parameters (M) | FPS |
|---|---|---|---|---|---|---|
| YOLOv5 | 0.974 | 0.948 | 0.986 | 0.780 | 2.51 | 92.59 |
| YOLOv8 | 0.972 | 0.968 | 0.988 | 0.806 | 3.10 | 125.00 |
| YOLOv9 | 0.974 | 0.948 | 0.988 | 0.803 | 2.00 | 50.00 |
| YOLOv10 | 0.955 | 0.943 | 0.981 | 0.790 | 2.71 | 103.09 |
| YOLOv11 | 0.961 | 0.973 | 0.986 | 0.786 | 2.59 | 121.95 |
| YOLOv12 | 0.966 | 0.963 | 0.988 | 0.779 | 2.57 | 88.50 |
| MOT Method | Re-ID | HOTA↑ | IDF1↑ | IDS↓ | FPS↑ |
|---|---|---|---|---|---|
| OC-SORT | 42.446 | 42.664 | 24 | 41.89 | |
| Deep-OC-SORT | ✓ | 42.540 | 42.131 | 24 | 17.48 |
| Strong-SORT | ✓ | 42.510 | 42.464 | 23 | 16.43 |
| ByteTrack | 42.909 | 42.516 | 24 | 41.94 | |
| BoT-SORT | ✓ | 43.289 | 42.915 | 20 | 16.18 |
| MAAT | 44.370 | 43.857 | 20 | 41.40 |
| ByteTrack | NSA-KF | DAAS | Fuse-Distance | HOTA ↑ | IDF1 ↑ | FPS ↑ |
|---|---|---|---|---|---|---|
| ✓ | × | × | × | 42.909 | 42.516 | 41.94 |
| ✓ | ✓ | × | × | 42.978 | 42.525 | 41.87 |
| ✓ | × | ✓ | × | 44.129 | 43.559 | 41.68 |
| ✓ | ✓ | ✓ | × | 44.342 | 43.587 | 41.53 |
| ✓ | ✓ | ✓ | ✓ | 44.37 | 43.857 | 41.4 |
Disclaimer/Publisher’s Note: The statements, opinions and data contained in all publications are solely those of the individual author(s) and contributor(s) and not of MDPI and/or the editor(s). MDPI and/or the editor(s) disclaim responsibility for any injury to people or property resulting from any ideas, methods, instructions or products referred to in the content. |
© 2026 by the authors. Licensee MDPI, Basel, Switzerland. This article is an open access article distributed under the terms and conditions of the Creative Commons Attribution (CC BY) license.
Share and Cite
Han, X.; Han, Q.; Fan, Y.; Mu, D. MAAT: A Marine-Aware Adaptive Tracker for Robust and Real-Time Multi-Object Tracking in Maritime Environments. J. Mar. Sci. Eng. 2026, 14, 738. https://doi.org/10.3390/jmse14080738
Han X, Han Q, Fan Y, Mu D. MAAT: A Marine-Aware Adaptive Tracker for Robust and Real-Time Multi-Object Tracking in Maritime Environments. Journal of Marine Science and Engineering. 2026; 14(8):738. https://doi.org/10.3390/jmse14080738
Chicago/Turabian StyleHan, Xinjie, Qi Han, Yunsheng Fan, and Dongdong Mu. 2026. "MAAT: A Marine-Aware Adaptive Tracker for Robust and Real-Time Multi-Object Tracking in Maritime Environments" Journal of Marine Science and Engineering 14, no. 8: 738. https://doi.org/10.3390/jmse14080738
APA StyleHan, X., Han, Q., Fan, Y., & Mu, D. (2026). MAAT: A Marine-Aware Adaptive Tracker for Robust and Real-Time Multi-Object Tracking in Maritime Environments. Journal of Marine Science and Engineering, 14(8), 738. https://doi.org/10.3390/jmse14080738