Robotic Welding Technologies for Intersecting and Irregular Pipes and Pipe Joints Toward Automated Production Line Integration: A Review




Abstract
1. Introduction
- (i)
- Systematically identifying and categorising research specifically on intersecting and irregular pipe joints;
- (ii)
- Highlighting gaps in trajectory planning, process parameter optimisation, sensing integration, and real-world implementation;
- (iii)
- Providing a structured reference framework to guide future research, particularly in energy-aware and human–robot collaborative welding.
2. Methodology
3. Categorisation
3.1. General Pipe Welding
3.2. Intersecting Pipes
3.3. Boiler and Tube-to-Tubesheet Welding
3.4. Control and Modelling
4. Conclusions
5. Further Research
Author Contributions
Funding
Institutional Review Board Statement
Informed Consent Statement
Data Availability Statement
Acknowledgments
Conflicts of Interest
References
- Kumar, P.; Mistry, J. Impact of Welding Processes on Environment and Health. Int. J. Adv. Res. Mech. Eng. Technol. 2015, 1, 17–20. [Google Scholar]
- Zhang, Y.M.; Yang, Y.-P.; Zhang, W.; Na, S.-J. Advanced Welding Manufacturing: A Brief Analysis and Review of Challenges and Solutions. J. Manuf. Sci. Eng. 2020, 142, 110816. [Google Scholar] [CrossRef] [Scilit]
- Antonini, J.M. Health Effects of Welding. Crit. Rev. Toxicol. 2003, 33, 61–103. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Knott, P.; Csorba, G.; Bennett, D.; Kift, R. Welding Fume: A Comparison Study of Industry Used Control Methods. Safety 2023, 9, 42. [Google Scholar] [CrossRef] [Scilit]
- Sotnikov, A.L.; Denisova, N.A.; Knyazkov, O.V.; Belelyubskii, B.F.; Balakhnina, E.E. Methodological Assessment of Human Factor Impact on the Reliability of Production System. Metallurgist 2025, 68, 1949–1958. [Google Scholar] [CrossRef] [Scilit]
- Liu, Y.K.; Zhang, W.J.; Zhang, Y.M. A Tutorial on Learning Human Welder’s Behavior: Sensing, Modeling, and Control. J. Manuf. Process. 2014, 16, 123–136. [Google Scholar] [CrossRef] [Scilit]
- Eren, B.; Demir, M.H.; Mistikoglu, S. Recent Developments in Computer Vision and Artificial Intelligence Aided Intelligent Robotic Welding Applications. Int. J. Adv. Manuf. Technol. 2023, 126, 4763–4809. [Google Scholar] [CrossRef] [Scilit]
- Al-Karkhi, N.K.; Abbood, W.T.; Khalid, E.A.; Al-Tamimi, A.N.J.; Kudhair, A.A.; Abdullah, O.I. Intelligent Robotic Welding Based on a Computer Vision Technology Approach. Computers 2022, 11, 155. [Google Scholar] [CrossRef] [Scilit]
- Liu, J.; Cai, Y.; Cao, Y. A Robot Path-Planning Method Based on an Improved Genetic Algorithm. Trans. FAMENA 2024, 48, 141–154. [Google Scholar] [CrossRef] [Scilit]
- Peta, K.; Wiśniewski, M.; Kotarski, M.; Ciszak, O. Comparison of Single-Arm and Dual-Arm Collaborative Robots in Precision Assembly. Appl. Sci. 2025, 15, 2976. [Google Scholar] [CrossRef] [Scilit]
- Peta, K.; Suszyński, M.; Wiśniewski, M.; Mitek, M. Analysis of Energy Consumption of Robotic Welding Stations. Sustainability 2024, 16, 2837. [Google Scholar] [CrossRef] [Scilit]
- Pires, J.N.; Loureiro, A.; Godinho, T.; Ferreira, P.; Fernando, B.; Morgado, J. Welding Robots. IEEE Robot. Autom. Mag. 2003, 10, 45–55. [Google Scholar] [CrossRef]
- Ťavodová, M.; Náprstková, N.; Hnilicová, M.; Beňo, P. Quality Evaluation of Welding Joints by Different Methods. FME Trans. 2020, 48, 816–824. [Google Scholar] [CrossRef] [Scilit]
- Fang, H.; Ong, S.; Nee, A.Y.C. Robot path planning optimization for welding complex joints. Int. J. Adv. Manuf. Technol. 2017, 90, 3829–3839. [Google Scholar] [CrossRef] [Scilit]
- He, Y.; Yu, Z.; Deng, Y.; Deng, J.; Cai, R.; Wang, Z.; Tu, W.; Zhong, W. AHP-based welding position decision and optimization for angular distortion and weld collapse control in T-joint multipass GMAW. J. Manuf. Process. 2024, 121, 246–259. [Google Scholar] [CrossRef] [Scilit]
- Liu, Y.; Tang, Q.; Tian, X. A discrete method of sphere–pipe intersecting curve for robot welding by offline programming. Robot. Comput.Integr. Manuf. 2019, 57, 404–411. [Google Scholar] [CrossRef] [Scilit]
- Ghariblu, H.; Shahabi, M. Path planning of complex pipe joints welding with redundant robotic systems. Robotica 2019, 37, 1020–1032. [Google Scholar] [CrossRef] [Scilit]
- Wang, Y.Q. Path planning of the intersecting line of cylindrical pipes welded by the welding robot. Appl. Mech. Mater. 2013, 456, 43–49. [Google Scholar] [CrossRef] [Scilit]
- Xiong, J.; Fu, Z.; Chen, H.; Pan, J.; Gao, X.; Chen, X. Simulation and trajectory generation of dual-robot collaborative welding for intersecting pipes. Int. J. Adv. Manuf. Technol. 2020, 111, 2231–2241. [Google Scholar] [CrossRef] [Scilit]
- Liu, Y.; Liu, J.; Tian, X. An approach to the path planning of intersecting pipes weld seam with the welding robot based on non-ideal models. Robot. Comput. Integr. Manuf. 2019, 55, 96–108. [Google Scholar] [CrossRef] [Scilit]
- Shi, L.; Tian, X.; Zhang, C. Automatic programming for industrial robot to weld intersecting pipes. Int. J. Adv. Manuf. Technol. 2015, 81, 2099–2107. [Google Scholar] [CrossRef] [Scilit]
- Zhang, W.; Li, J. The application of intelligent welding robots and visual detection algorithms in building steel structures. Scalable Comput. Pract. Exp. 2024, 25, 4265–4273. [Google Scholar] [CrossRef] [Scilit]
- Madsen, O.; Bro Sørensen, C.; Larsen, R.; Overgaard, L.; Jacobsen, N.J. A system for complex robotic welding. Ind. Robot 2002, 29, 127–131. [Google Scholar] [CrossRef] [Scilit]
- Lima, E.J.; Queiroz Bracarense, A. Trajectory generation in robotic shielded metal arc welding during execution time. Ind. Robot 2009, 36, 19–26. [Google Scholar] [CrossRef] [Scilit]
- Mobaraki, M.; Ahani, S.; Gonzalez, R.; Yi, K.M.; Van Heusden, K.; Dumont, G.A. Vision-based seam tracking for GMAW fillet welding based on keypoint detection deep learning model. J. Manuf. Process. 2024, 117, 315–328. [Google Scholar] [CrossRef] [Scilit]
- Ou, J.; Wang, X.; Lin, Y. Research on three-dimensional positioning method of casing welds based on binocular vision. In Ninth International Symposium on Precision Mechanical Measurements; You, Z., Ed.; SPIE: Bellingham, WA, USA, 2019; p. 111. [Google Scholar] [CrossRef] [Scilit]
- Asadi, M.; Ashoori, A.; Afshar, M.; Sheikhshab, A.; Scheerer, T.; Kaspardlov, A.; Bagheri, S.; Firouz, S.; Karimzadeh, S. Vision-driven adaptive welding solutions for the top three challenges in welding fabrication. Weld. World 2025, 69, 1277–1289. [Google Scholar] [CrossRef] [Scilit]
- Sekhar, N.C.; Bjørneklett, B. Laser welding of complex aluminium structures. Sci. Technol. Weld. Join. 2002, 7, 19–25. [Google Scholar] [CrossRef] [Scilit]
- Kim, J.-D.; Lee, C.-J. Study on laser welding of automotive modular steering gear housing by using multi-axis control. J. Weld. Join. 2008, 26, 59–66. [Google Scholar] [CrossRef] [Scilit]
- Liu, K.; Sheng, Z.; Zhang, W.; Zhong, Z.; Yang, X.; Chen, H.; Xiao, R. A novel robotic multi-layer multi-pass welding adaptive path generation method based on point cloud slicing and Transformer for saddle-shaped weld seams. J. Manuf. Process. 2025, 141, 1578–1594. [Google Scholar] [CrossRef] [Scilit]
- Jiahao, O.; Xian, W.; Zhou, X. An identification method for casing weld in complex environment. In Tenth International Symposium on Precision Engineering Measurements and Instrumentation; Tan, J., Lin, J., Eds.; SPIE: Bellingham, WA, USA, 2019; p. 187. [Google Scholar] [CrossRef] [Scilit]
- Iovanas, R.; Joni, A.; Staretu, I.; Iovanaș, D.M.; Iovanas, R.F. The anthropomorphic six axis robot as an appropriate tool for automatic gas pipe welding process. Appl. Mech. Mater. 2012, 162, 455–462. [Google Scholar] [CrossRef] [Scilit]
- Lima, E.J.; Fortunato Torres, G.C.; Felizardo, I.; Ramalho Filho, F.A.; Bracarense, A.Q. Development of a robot for orbital welding. Ind. Robot 2005, 32, 321–325. [Google Scholar] [CrossRef] [Scilit]
- Zheng, L.; Ji, A.; Cheng, Y.; Qin, G.; Zhang, W.; Zhang, Y.; Wang, C.; Han, H. Design and development of automatic pipe cutting and welding robot for fusion reactor. Fusion Eng. Des. 2024, 205, 114555. [Google Scholar] [CrossRef] [Scilit]
- Silva, R.H.G.E.; Galeazzi, D.; Schwedersky, M.B.; Mendonça, F.K.; Bonamigo, A.V.; Marques, C. An adaptive orbital system based on laser vision sensor for pipeline GMAW welding. J. Braz. Soc. Mech. Sci. Eng. 2021, 43, 358. [Google Scholar] [CrossRef] [Scilit]
- Kindermann, R.M.; Silva, R.H.G.E.; Dutra, J.C. Development and Validation of Algorithms Employed for Sensor Systems in Robotic Orbital Root Pass Welding of Pipelines. Soldag. Inspeção 2015, 20, 391–402. [Google Scholar] [CrossRef] [Scilit]
- Yin, T.; Wang, J.; Zhao, H.; Zhou, L.; Xue, Z.; Wang, H. Research on Filling Strategy of Pipeline Multi-Layer Welding for Compound Narrow Gap Groove. Materials 2022, 15, 5967. [Google Scholar] [CrossRef] [Scilit]
- Kim, J.-D.; Song, M.-K.; Lee, C.-J.; Moon, C.-H.; Lee, J.-R. Study on Welding Systems for Efficient Joining of Stainless Steel Pipes (I)—Development of a Four-Axes Control Automatic Welding System. J. Korean Soc. Mar. Eng. 2017, 41, 819–824. [Google Scholar] [CrossRef] [Scilit]
- Wang, Y.; Lee, W.; Jang, S.; Truong, V.D.; Jeong, Y.; Won, C.; Lee, J.; Yoon, J. Prediction of Internal Welding Penetration Based on IR Thermal Image Supported by Machine Vision and ANN-Model during Automatic Robot Welding Process. J. Adv. Join. Process. 2024, 9, 100199. [Google Scholar] [CrossRef] [Scilit]
- Silva, R.H.G.E.; Schwedersky, M.B.; Rosa, Á.F.D. Evaluation of Toptig Technology Applied to Robotic Orbital Welding of 304L Pipes. Int. J. Press. Vessel. Pip. 2020, 188, 104229. [Google Scholar] [CrossRef] [Scilit]
- Bae, K.-Y.; Lee, T.-H.; Ahn, K.-C. An Optical Sensing System for Seam Tracking and Weld Pool Control in Gas Metal Arc Welding of Steel Pipe. J. Mater. Process. Technol. 2002, 120, 458–465. [Google Scholar] [CrossRef] [Scilit]
- Habibkhah, F.; Moallem, M. Application of Machine Learning for Seam Profile Identification in Robotic Welding. Mach. Learn. Appl. 2025, 20, 100633. [Google Scholar] [CrossRef] [Scilit]
- Chen, X.; Dharmawan, A.G.; Foong, S.; Soh, G.S. Seam Tracking of Large Pipe Structures for an Agile Robotic Welding System Mounted on Scaffold Structures. Robot. Comput. Integr. Manuf. 2018, 50, 242–255. [Google Scholar] [CrossRef] [Scilit]
- Chen, S.; Shen, W. Design of Cylindrical Pipe Automatic Welding Control System Based on STM32. AIP Conf. Proc. 2018, 1995, 040110. [Google Scholar] [CrossRef] [Scilit]
- Wang, T.; Meng, K.; Cui, L.; Li, X. Weld Tracking Technology for All-Position Welding of Pipes Based on Laser Vision. Opt. Lasers Eng. 2025, 188, 108912. [Google Scholar] [CrossRef] [Scilit]
- Somasundar, A.V.S.S.; Yedukondalu, G. Six DOF robot: Inverse kinematics solution to path planning for intersecting pipes for welding operation and inverse Jacobian comparison. Int. J. Interact. Des. Manuf. 2024, 18, 3313–3322. [Google Scholar] [CrossRef] [Scilit]
- Liu, Y.; Zhao, J.; Chen, S.; Lu, Z. Type and dimension synthesis of a portable all-position welding robot. Ind. Robot 2010, 37, 293–301. [Google Scholar] [CrossRef] [Scilit]
- Wu, H.W.; Cai, Y.Q.; Geng, Z.H. Numerical simulation of intersecting line workpiece welded by arc robot welding. Metalurgija 2024, 63, 407–409. [Google Scholar]
- Liu, Y.; Ren, L.; Tian, X. A robot welding approach for the sphere-pipe joints with swing and multi-layer planning. Int. J. Adv. Manuf. Technol. 2019, 105, 265–278. [Google Scholar] [CrossRef] [Scilit]
- Han, G.; Zhou, Y.; Chen, X.; Peng, Y.; Xiao, W.; Gong, L. Multi-layer and multi-pass welding trajectory planning of thick-walled pipes intersecting curve in a pressure vessel. Int. J. Comput. Integr. Manuf. 2025, 38, 1741–1764. [Google Scholar] [CrossRef] [Scilit]
- Zhang, T.; Ouyang, F. Offline motion planning and simulation of two-robot welding coordination. Front. Mech. Eng. 2012, 7, 81–92. [Google Scholar] [CrossRef] [Scilit]
- Liu, Y.; Tian, X. Robot path planning with two-axis positioner for non-ideal sphere-pipe joint welding based on laser scanning. Int. J. Adv. Manuf. Technol. 2019, 105, 1295–1310. [Google Scholar] [CrossRef] [Scilit]
- Vosniakos, G.-C.; Katsaros, P.; Papagiannoulis, I.; Meristoudi, E. Development of robotic welding stations for pressure vessels: Interactive digital manufacturing approaches. Int. J. Interact. Des. Manuf. 2022, 16, 151–166. [Google Scholar] [CrossRef] [Scilit]
- Hong, L.; Wang, B.; Xu, Z.; Yan, Z. Research on off-line programming method of spatial intersection curve welding based on VTK. Int. J. Adv. Manuf. Technol. 2020, 106, 1587–1599. [Google Scholar] [CrossRef] [Scilit]
- Liu, Y. Pose Planning for the End-Effector of Robot in the Welding of Intersecting Pipes. Chin. J. Mech. Eng. 2011, 24, 264. [Google Scholar] [CrossRef] [Scilit]
- Liu, Y.; Tang, Q.; Tian, X.; Yang, S. A Novel Offline Programming Approach of Robot Welding for Multi-Pipe Intersection Structures Based on NSGA-II and Measured 3D Point-Clouds. Robot. Comput. Integr. Manuf. 2023, 83, 102549. [Google Scholar] [CrossRef] [Scilit]
- Geng, Y.; Zhang, Y.; Tian, X.; Zhou, L. A Novel 3D Vision-Based Robotic Welding Path Extraction Method for Complex Intersection Curves. Robot. Comput. Integr. Manuf. 2024, 87, 102702. [Google Scholar] [CrossRef] [Scilit]
- Chen, C.; Hu, S.; He, D.; Shen, J. An Approach to the Path Planning of Tube–Sphere Intersection Welds with the Robot Dedicated to J-Groove Joints. Robot. Comput. Integr. Manuf. 2013, 29, 41–48. [Google Scholar] [CrossRef] [Scilit]
- Bonser, G. Robotic Gas Metal Arc Welding of Small Diameter Saddle Type Joints Using Multistripe Structured Light. Opt. Eng. 1999, 38, 1943. [Google Scholar] [CrossRef] [Scilit]
- Shi, L.; Tian, X. Automation of Main Pipe-Rotating Welding Scheme for Intersecting Pipes. Int. J. Adv. Manuf. Technol. 2015, 77, 955–964. [Google Scholar] [CrossRef] [Scilit]
- Shahabi, M.; Ghariblu, H.; Beschi, M.; Pedrocchi, N. Path Planning Methodology for Multi-Layer Welding of Intersecting Pipes Considering Collision Avoidance. Robotica 2021, 39, 945–958. [Google Scholar] [CrossRef] [Scilit]
- Zhang, Y.; Lv, X.; Xu, L.; Jing, H.; Han, Y. A Segmentation Planning Method Based on the Change Rate of Cross-Sectional Area of Single V-Groove for Robotic Multi-Pass Welding in Intersecting Pipe-Pipe Joint. Int. J. Adv. Manuf. Technol. 2019, 101, 23–38. [Google Scholar] [CrossRef] [Scilit]
- Shahabi, M.; Ghariblu, H.; Beschi, M. Comparison of Different Sample-Based Motion Planning Methods in Redundant Robotic Manipulators. Robotica 2022, 40, 3104–3119. [Google Scholar] [CrossRef] [Scilit]
- Xia, S.; Pang, C.K.; Mamun, A.A.; Wong, F.S.; Chew, C.-M. Robotic Welding for Filling Shape-Varying Geometry Using Weld Profile Control with Data-Driven Fast Input Allocation. Mechatronics 2021, 79, 102657. [Google Scholar] [CrossRef] [Scilit]
- Stockie, J.M. The Geometry of Intersecting Tubes Applied to Controlling a Robotic Welding Torch. Maple Tech 1998, 19, 2. [Google Scholar]
- Xue, L.; Wei, M.; Yang, T.; Lu, Y.; Shi, N.; Zhang, Z. Interpolation Algorithm and Mathematical Model in Automated Welding of Saddle-Shaped Weld. Model. Simul. Eng. 2018, 2018, 8045162. [Google Scholar] [CrossRef] [Scilit]
- Chen, Y.; Hu, Q. Dual-Robot Stud Welding System for Membrane Wall. Ind. Robot 2022, 49, 132–140. [Google Scholar] [CrossRef] [Scilit]
- Ji, X.; Chen, Y.; Yang, S. Stud Welding System Using an Industrial Robot for Membrane Walls. Int. J. Adv. Manuf. Technol. 2022, 121, 8467–8477. [Google Scholar] [CrossRef] [Scilit]
- Ding, Y.; Su, H.; Zhang, R.; Zhao, W.; Cui, X. Research on Automatic Guidance Technology of Tube-Sheet Welding Based on Vision and Laser Displacement Sensor. IEEE Access 2025, 13, 68141–68151. [Google Scholar] [CrossRef] [Scilit]
- Lei, T.; Huang, Y.; Wang, H.; Rong, Y. Automatic Weld Seam Tracking of Tube-to-Tubesheet TIG Welding Robot with Multiple Sensors. J. Manuf. Process. 2021, 63, 60–69. [Google Scholar] [CrossRef] [Scilit]
- Cai, J.; Lei, T. An Autonomous Positioning Method of Tube-to-Tubesheet Welding Robot Based on Coordinate Transformation and Template Matching. IEEE Robot. Autom. Lett. 2021, 6, 787–794. [Google Scholar] [CrossRef] [Scilit]
- Ma, J.; Wang, X.; Kong, J.; Rong, Y.; Huang, Y. Tube Sheet Annular Seam Measurement Technology Based on Laser Collaboration with Vision Sensor. IEEE Access 2023, 11, 47491–47500. [Google Scholar] [CrossRef] [Scilit]
- Rao, M.; Liu, K.; Sheng, Z.; Xiao, R.; Yang, X.; Zhang, W.; Zhong, Z.; Lu, Y.; Chen, H. A Novel Filling Strategy for Robotic Multi-Layer and Multi-Pass Welding Based on Point Clouds for Saddle-Shaped Weld Seams. J. Manuf. Process. 2024, 121, 233–245. [Google Scholar] [CrossRef] [Scilit]
- Wang, H.; Rong, Y.; Liu, C.; Huang, Y. Construction of a Semi-Dense Point Cloud Model for a Tube-to-Tubesheet Welding Robot. IET Collab. Intell. Manuf. 2022, 4, 220–231. [Google Scholar] [CrossRef] [Scilit]
- Dutra, J.C.; Bonacorso, N.G.; Silva, R.H.G.E.; Carvalho, R.S.; Silva, F.C. Development of a flexible robotic welding system for weld overlay cladding of thermoelectrical plants’ boiler tube walls. Mechatronics 2014, 24, 416–425. [Google Scholar] [CrossRef] [Scilit]
- Jin, Z.; Li, H.; Zhang, C.; Wang, Q.; Gao, H. Online welding path detection in automatic tube-to-tubesheet welding using passive vision. Int. J. Adv. Manuf. Technol. 2017, 90, 3075–3084. [Google Scholar] [CrossRef] [Scilit]
- Lei, T.; Wu, C.; Rong, Y.; Huang, Y. The development of tube-to-tubesheet welding from automation to digitization. Int. J. Adv. Manuf. Technol. 2021, 116, 779–802. [Google Scholar] [CrossRef] [Scilit]
- Yao, S.; Xue, L.; Huang, J.; Chen, B.; Zhang, R.; Han, F. Research and experiment on a mobile welding robot for expandable convoluted pipe. Sci. Rep. 2025, 15, 8219. [Google Scholar] [CrossRef] [Scilit]
- Muramatsu, M.; Suga, Y.; Mori, K. Autonomous mobile robot system for monitoring and control of penetration during fixed pipes welding. JSME Int. J. Ser. A 2003, 46, 391–397. [Google Scholar] [CrossRef] [Scilit]
- Liu, Y.K.; Shao, Z.; Zhang, Y.M. Learning human welder movement in pipe GTAW: A virtualized welding approach. Weld. J. 2014, 93, 388–398. [Google Scholar]
- Dong, X.; Feng, Q.; Xia, J.; Zhang, Y. Positioning method of positive circular weld with left and right swing interferences of robot. Laser Optoelectron. Prog. 2022, 59, 1215007. [Google Scholar] [CrossRef] [Scilit]
- Arko, P.; Jezeršek, M. Automatic calibration of the adaptive 3D scanner-based robot welding system. Front. Robot. AI 2022, 9, 876717. [Google Scholar] [CrossRef] [Scilit]
- Yue, H.; Li, K.; Zhao, H.; Zhang, Y. Vision-based pipeline girth-welding robot and image processing of weld seam. Ind. Robot 2009, 36, 284–289. [Google Scholar] [CrossRef] [Scilit]
- Rezaee, A. Determining PID controller coefficients for the moving motor of a welder robot using fuzzy logic. Autom. Control Comput. Sci. 2017, 51, 124–132. [Google Scholar] [CrossRef] [Scilit]
- Gan, Y.; Duan, J.; Chen, M.; Dai, X. Multi-robot trajectory planning and position/force coordination control in complex welding tasks. Appl. Sci. 2019, 9, 924. [Google Scholar] [CrossRef] [Scilit]
- Lei, T.; Wu, C.; Yu, H. Electric arc length control of circular seam in welding robot based on arc voltage sensing. IEEE Sens. J. 2022, 22, 3326–3333. [Google Scholar] [CrossRef] [Scilit]
- Miyasaka, F.; Yamane, Y.; Ohji, T. Development of circumferential TIG welding process model: A simulation model for welding of pipe and plate. Sci. Technol. Weld. Join. 2005, 10, 521–527. [Google Scholar] [CrossRef] [Scilit]
- Lauridsen, J.K.; Madsen, O.; Holm, H.; Hafsteinsson, I.; Boelskifte, J. Model based control of a one degree of freedom workpiece manipulator for welding of nozzles. Math. Comput. Simul. 1996, 41, 407–417. [Google Scholar] [CrossRef] [Scilit]
- Lima, E.J.; Souza, H.A.D.M.; Kienitz, K.M.; Ramalho Filho, F.A. Closed-form solution for direct and inverse kinematic models of a parallel manipulator for robotic orbital welding. J. Braz. Soc. Mech. Sci. Eng. 2020, 42, 74. [Google Scholar] [CrossRef] [Scilit]
- Doodman Tipi, A. The study on the drop detachment for automatic pipeline GMAW system: Free flight mode. Int. J. Adv. Manuf. Technol. 2010, 50, 137–147. [Google Scholar] [CrossRef] [Scilit]
- Fridenfalk, M.; Bolmsjö, G. Design and validation of a universal 6D seam tracking system in robotic welding based on laser scanning. Ind. Robot 2003, 30, 437–448. [Google Scholar] [CrossRef] [Scilit]
- Shim, J.-Y.; Zhang, J.-W.; Yoon, H.-Y.; Kang, B.-Y.; Kim, I.-S. Prediction model for bead reinforcement area in automatic gas metal arc welding. Adv. Mech. Eng. 2018, 10, 1687814018781492. [Google Scholar] [CrossRef] [Scilit]
- Tang, L.; Yang, M.; Hou, Z. Simulation of three-dimensional temperature field in high-frequency welding based on nonlinear finite element method. Nonlinear Eng. 2023, 12, 20220316. [Google Scholar] [CrossRef] [Scilit]
- Li, J.; Chen, Z.; Rao, G.; Xu, J. Structured light-based visual servoing for robotic pipe welding pose optimization. IEEE Access 2019, 7, 138327–138340. [Google Scholar] [CrossRef] [Scilit]
- Gao, J.; Li, F.; Zhang, C.; He, W.; He, J.; Chen, X. A Method of D-Type Weld Seam Extraction Based on Point Clouds. IEEE Access 2021, 9, 65401–65410. [Google Scholar] [CrossRef] [Scilit]
- Li, Y.; Xu, Y.; Wang, X.; Ma, X.; Wang, Q.; Zhang, H. A Feature-Extraction Localization Algorithm Research for Teaching-Free Automated Robotic Welding Based on 3D Point Cloud. Int. J. Adv. Manuf. Technol. 2025, 138, 5397–5412. [Google Scholar] [CrossRef] [Scilit]
- Bauer, A.; Manurung, Y.H.P.; Sprungk, J.; Graf, M.; Awiszus, B.; Prajadhiana, K. Investigation on Forming–Welding Process Chain for DC04 Tube Manufacturing Using Experiment and FEM Simulation. Int. J. Adv. Manuf. Technol. 2019, 102, 2399–2408. [Google Scholar] [CrossRef] [Scilit]
- Kim, J.-S.; Lee, J.-P.; Park, M.-H.; Park, C.-K.; Kim, I.-S. A Study on Prediction of the Optimal Process Parameters for GMA Root-Pass Welding in Pipeline. Procedia Eng. 2014, 97, 723–731. [Google Scholar] [CrossRef] [Scilit]
- Chandra, M.; Vimal, K.E.K.; Rajak, S. A Comparative Study of Machine Learning Algorithms in the Prediction of Bead Geometry in Wire-Arc Additive Manufacturing. Int. J. Interact. Des. Manuf. 2024, 18, 6625–6638. [Google Scholar] [CrossRef] [Scilit]





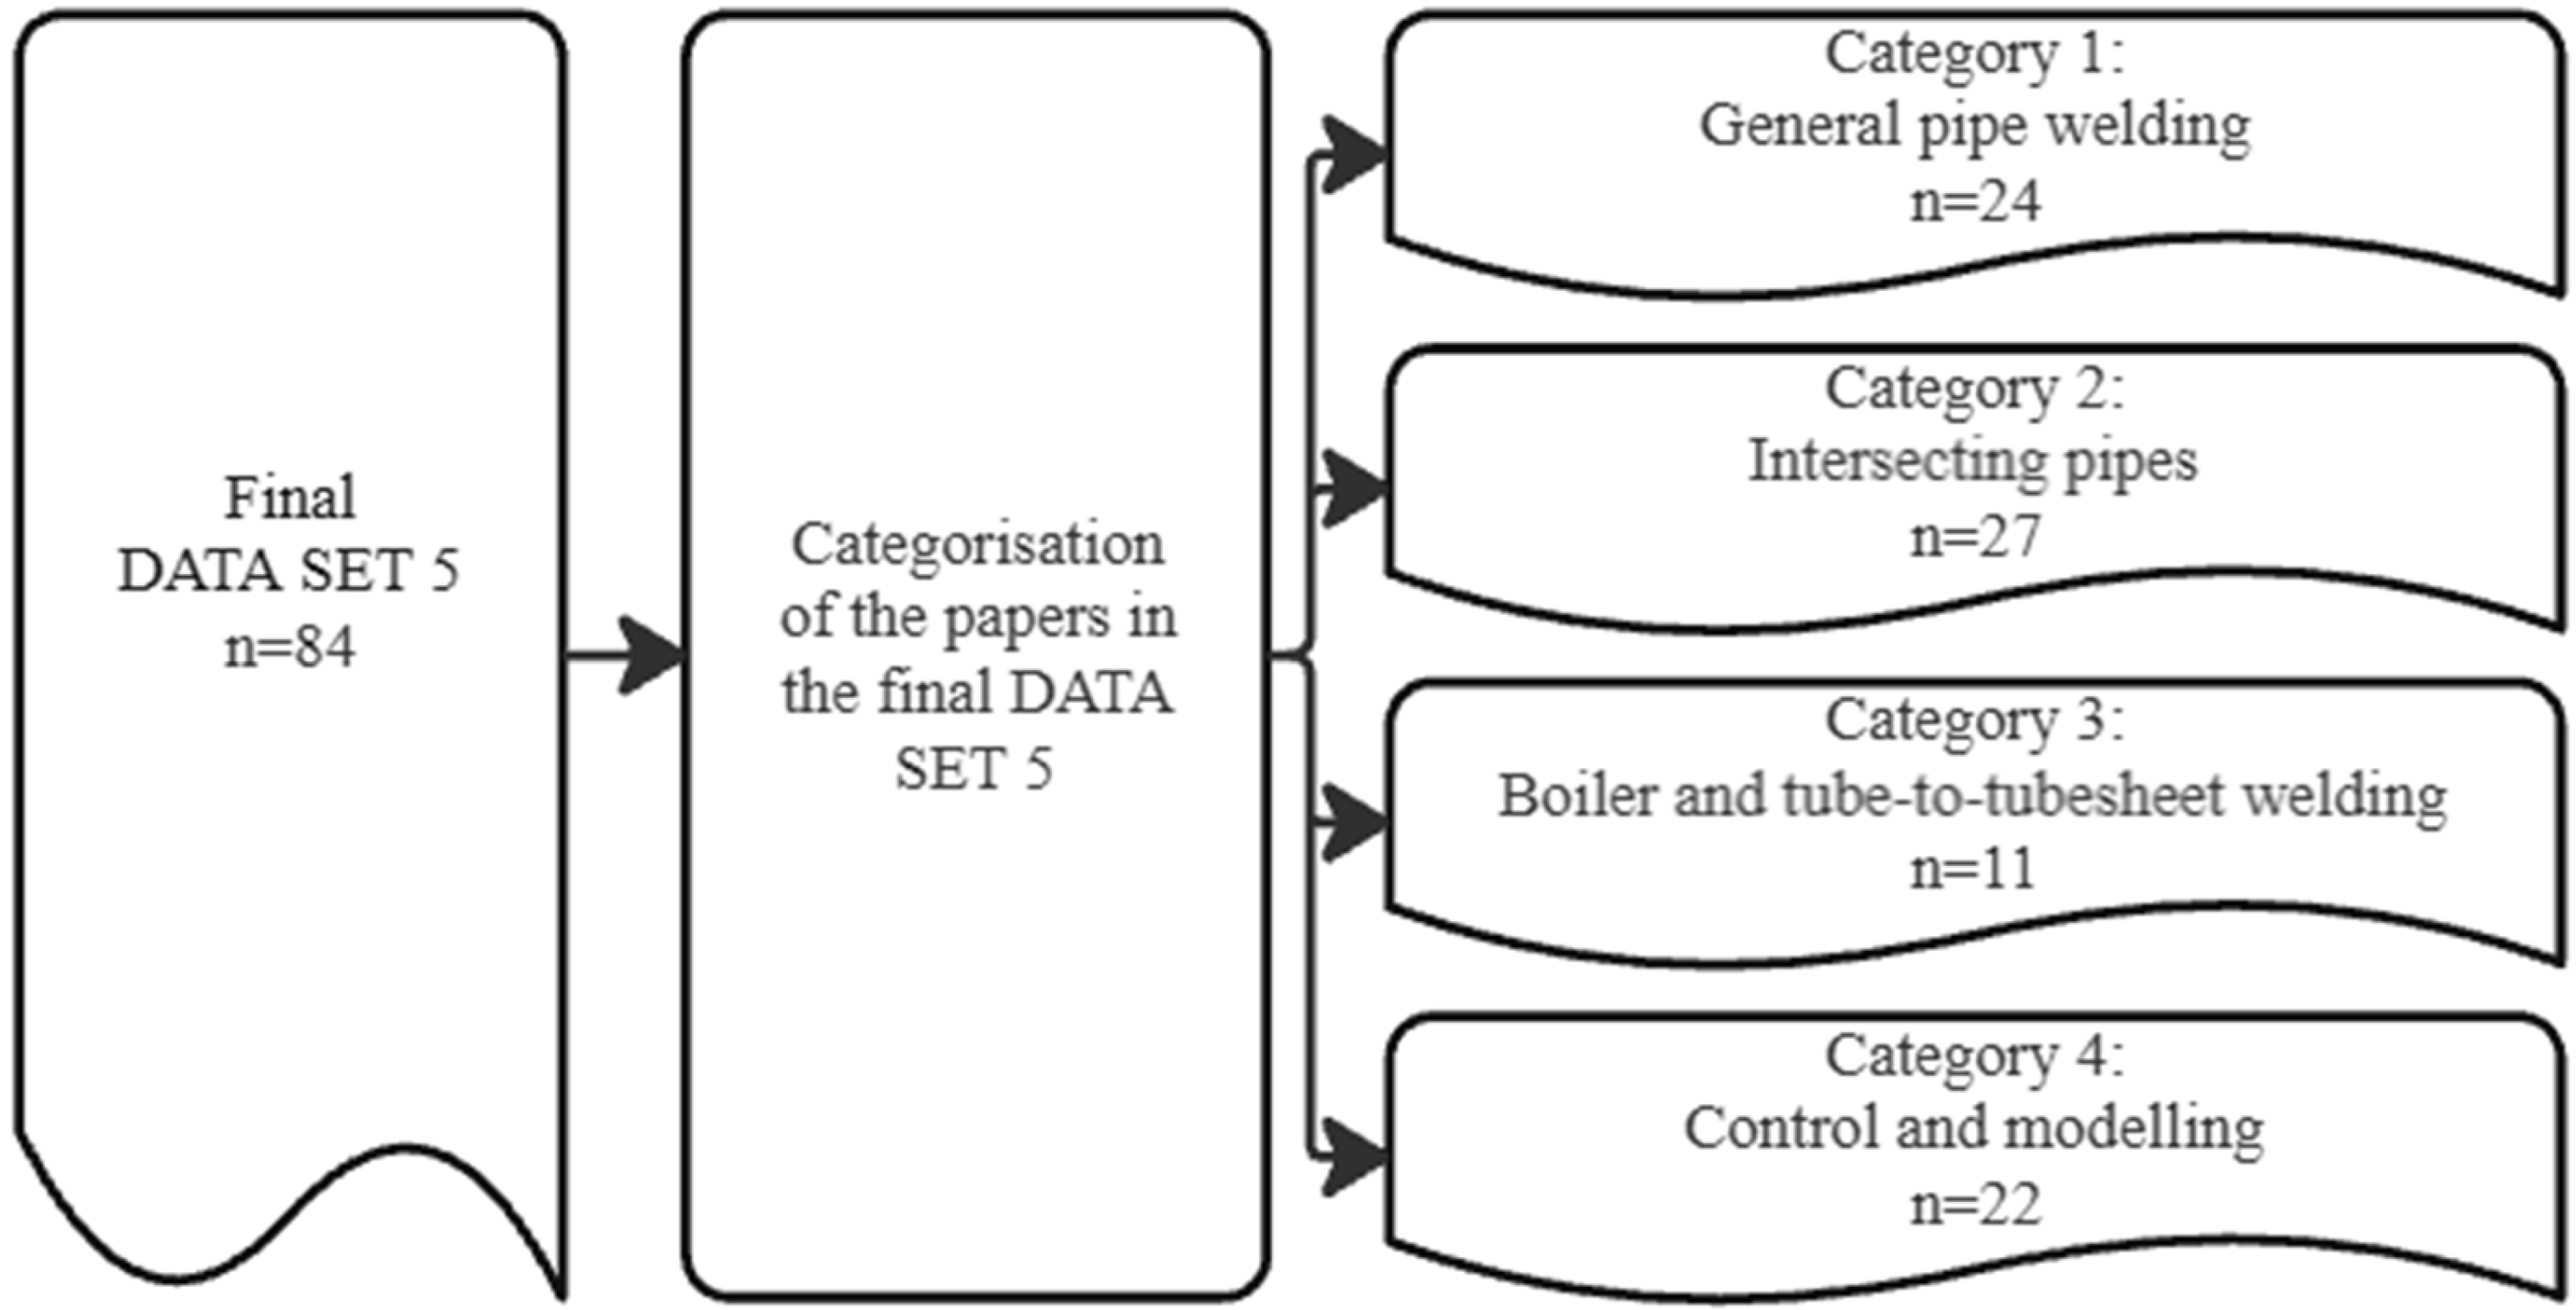
| Category | IDs |
|---|---|
| General pipe welding | [22,23,24,25,26,27,28,29,30,31,32,33,34,35,36,37,38,39,40,41,42,43,44,45] |
| Intersecting pipes | [16,17,18,19,20,21,46,47,48,49,50,51,52,53,54,55,56,57,58,59,60,61,62,63,64,65,66] |
| Boiler and tube-to-tubesheet welding | [67,68,69,70,71,72,73,74,75,76,77] |
| Control and modelling | [78,79,80,81,82,83,84,85,86,87,88,89,90,91,92,93,94,95,96,97,98,99] |
| Category | IDs |
|---|---|
| Robots for complex industrial scenarios and unstructured environments | [22,23] |
| Sensor systems and advanced positioning | [25,26,31] |
| Adaptive control and data-driven learning | [27] |
| Multi-layer and multi-pass path generation | [30] |
| Welding technologies and their automation | [24,28,29] |
| Mechanical design and orbital systems | [33,34,38,44] |
| Process control and optimisation | [37,40] |
| Sensor systems and weld tracking | [35,36,41] |
| Computer vision and artificial intelligence for seam recognition | [39,42,43,45] |
| Application of standard industrial robots | [32] |
| Category | IDs |
|---|---|
| Robot path planning and programming | [16,17,18,20,21,46,54,56,61,63,66] |
| Multi-robot coordination and collaboration | [19,51] |
| Sensors, laser systems, and 3D vision | [52,57,59] |
| Parameter optimisation and quality control | [48,64] |
| Joint mathematics and geometry | [65] |
| Specific methods for particular joints and techniques | [49,50,58,60,62] |
| Robotic system development and design | [47,53,55] |
| ID | Technical Focus | Validation Level | Type of Robotic Control | Integration Level | Quantitative Metrics Reported |
|---|---|---|---|---|---|
| [16] | Trajectory planning for sphere-pipe welding | Simulation only | Offline programming | Single-module contribution | Qualitative only |
| [17] | Trajectory planning | Simulation only | Offline programming | Single-module contribution | Qualitative only |
| [18] | Trajectory planning | Example-based (programmable drawing software) | Offline programming | Single-module contribution | Qualitative only |
| [19] | Multi-robot coordination | Simulation only | Offline programming | Multi-module integration | None |
| [20] | Mathematical modelling + trajectory planning | Laboratory experiment | Offline programming | Multi-module integration | Qualitative only |
| [21] | Automatic programming + trajectory planning | Laboratory experiment | Offline programming | Multi-module integration | Qualitative only |
| [46] | Trajectory planning | Simulation only | Offline programming | Single-module contribution | Accuracy reported |
| [47] | Robotic system design | Prototype development (laboratory) | N/A * | Full robotic system implementation | None |
| [48] | Numerical modelling | Simulation only | N/A * | Single-module contribution | Accuracy reported |
| [49] | Trajectory planning + welding strategy | Laboratory experiment (with simulation) | Semi-adaptive (model-based attitude adjustment) | Multi-module integration | Qualitative only |
| [50] | Multi-robot trajectory planning | Laboratory experiment | Offline programming | Multi-module integration | Accuracy reported |
| [51] | Multi-robot coordination | Simulation only | Offline programming | Multi-module integration | Qualitative only |
| [52] | Path planning | Simulation only | Semi-adaptive (model-based) | Multi-module integration | Qualitative only |
| [53] | Robotic cell design + path planning | Simulation only | Offline programming | Multi-module integration | Qualitative only |
| [54] | Offline spatial intersection curve programming | Laboratory experiment | Offline programming | Single-module contribution | Qualitative only |
| [55] | End-effector pose planning | Simulation only | Offline programming | Single-module contribution | Qualitative only |
| [56] | Multi-pipe intersection offline programming | Laboratory experiment (with simulation) | Offline programming | Multi-module integration | Qualitative only |
| [57] | 3D vision-based path extraction | Laboratory experiment | Real-time adaptive/semi-autonomous | Multi-module integration | Qualitative only |
| [58] | Tube–sphere intersection path planning | Laboratory experiment | Offline programming | Multi-module integration | Accuracy reported |
| [59] | Vision-based seam tracking for saddle joints | Laboratory/Industrial experiment | Semi-adaptive (pre-welding) | Multi-module integration | Accuracy reported |
| [60] | Automatic main-pipe rotation welding for intersecting pipes | Laboratory experiment (with simulation) | Offline programming/Partial real-time interpolation | Multi-module integration | Qualitative only |
| [61] | Trajectory planning + collision avoidance | Simulation only | Offline programming | Single-module contribution | Qualitative only |
| [62] | Trajectory planning + multi-robot coordination + multi-layer strategy | Laboratory experiment (with simulation) | Semi-adaptive (model-based, dual-robot cooperation) | Multi-module integration | Accuracy reported |
| [63] | Sample-based motion planning | Simulation only | Offline programming | Single-module contribution | Performance metrics reported |
| [64] | Welding profile control + data-driven input allocation | Laboratory experiment | Real-time adaptive | Multi-module integration | Accuracy reported |
| [65] | Geometric modelling of intersecting tubes | Simulation only | Offline programming | Single-module contribution | Qualitative only |
| [66] | Interpolation algorithm + mathematical model | Laboratory experiment (with simulation) | Semi-adaptive (interpolation-based control) | Multi-module integration | Qualitative only |
| Category | IDs |
|---|---|
| Robotic welding of membrane walls | [67,68] |
| Tube-to-tubesheet welding and multi-sensor systems | [70,72,74,77] |
| 3D vision and laser-based positioning in welding | [69,71,73,75,76] |
| Category | IDs |
|---|---|
| Kinematic modelling and simulations | [89,93,96,97] |
| Welding process modelling | [87,90,92] |
| Robotic system control | [82,84,85,86,98,99] |
| Visual servoing and sensor-based approaches | [78,79,80,81,83,88,91,94,95] |
| ID | Control Strategy | Modelling Approach | Sensor Used | Validation Category |
|---|---|---|---|---|
| [7] | Guide control | Geometric modelling | No | Prototype test |
| [79] | Adaptive control system | Monitoring | Yes | Experiments |
| [80] | Human-in-the-loop control | Human imitation learning | Yes | Experiments |
| [81] | Optimisation-based Estimation Strategy | Geometric imaging model | Yes | Experiments |
| [82] | Adaptive control system | System calibration | Yes | Experiments |
| [83] | Adaptive control system | Image processing | Yes | Experiments |
| [84] | Closed-loop | Proportional–Integral– Derivative (PID) control | No | Simulation |
| [85] | Adaptive control system | Cooperative model | Yes | Simulation and Experiments |
| [86] | Closed-loop | Arc voltage tracking | Yes | Experiments |
| [87] | N/A * | Virtual welding | No | Simulation |
| [88] | Algorithm | Workpiece manipulator | No | Experiments |
| [89] | Closed-form solutions | Inverse and Direct Kinematics | No | Simulation |
| [90] | Open-loop simulation | Numerical simulation | Yes | Simulation and Experiments |
| [91] | Seam-tracking control system | Sensor-driven control modelling | Yes | Simulation |
| [92] | Predictive model control | Machine learning model | No | Statistical validation |
| [93] | Offline parametric optimisation | Numerical analysis | No | Simulation and Experiments |
| [94] | Closed-loop | Geometric modelling | Yes | Simulation and Experiments |
| [95] | Vision-guided robotic control | Welding seam extraction method | Yes | Experiments |
| [96] | Closed-loop, sensor-based adaptive control | 3D Point Cloud Seam Extraction | Yes | Simulation and Experiments |
| [97] | Offline optimisation | Chained process simulation | Yes | Simulation and Experiments |
| [98] | Control algorithm | Statistical model approach | N/A * | Experiments |
| [99] | Data-driven predictive control | Data-driven modelling | N/A * | Experiments |
Disclaimer/Publisher’s Note: The statements, opinions and data contained in all publications are solely those of the individual author(s) and contributor(s) and not of MDPI and/or the editor(s). MDPI and/or the editor(s) disclaim responsibility for any injury to people or property resulting from any ideas, methods, instructions or products referred to in the content. |
© 2026 by the authors. Licensee MDPI, Basel, Switzerland. This article is an open access article distributed under the terms and conditions of the Creative Commons Attribution (CC BY) license.
Share and Cite
Cajner, H.; Vlašić, P.; Ložar, V.; Golec, M.; Trstenjak, M. Robotic Welding Technologies for Intersecting and Irregular Pipes and Pipe Joints Toward Automated Production Line Integration: A Review. Appl. Sci. 2026, 16, 2974. https://doi.org/10.3390/app16062974
Cajner H, Vlašić P, Ložar V, Golec M, Trstenjak M. Robotic Welding Technologies for Intersecting and Irregular Pipes and Pipe Joints Toward Automated Production Line Integration: A Review. Applied Sciences. 2026; 16(6):2974. https://doi.org/10.3390/app16062974
Chicago/Turabian StyleCajner, Hrvoje, Patrik Vlašić, Viktor Ložar, Matija Golec, and Maja Trstenjak. 2026. "Robotic Welding Technologies for Intersecting and Irregular Pipes and Pipe Joints Toward Automated Production Line Integration: A Review" Applied Sciences 16, no. 6: 2974. https://doi.org/10.3390/app16062974
APA StyleCajner, H., Vlašić, P., Ložar, V., Golec, M., & Trstenjak, M. (2026). Robotic Welding Technologies for Intersecting and Irregular Pipes and Pipe Joints Toward Automated Production Line Integration: A Review. Applied Sciences, 16(6), 2974. https://doi.org/10.3390/app16062974