Article

Redundantly Actuated Hydraulic Shaking Tables via Dual-Loop Fuzzy Control

1
School of Mechanical Engineering, Taiyuan University of Science and Technology, Main Campus, Taiyuan 030024, China
2
Taiyuan Fortucky Logistics Equipment & Technology Co., Ltd., Taiyuan 030000, China
*
Author to whom correspondence should be addressed.
Appl. Sci. 2026, 16(3), 1505; https://doi.org/10.3390/app16031505
Submission received: 7 January 2026 / Revised: 27 January 2026 / Accepted: 29 January 2026 / Published: 2 February 2026
(This article belongs to the Section Mechanical Engineering)

Abstract

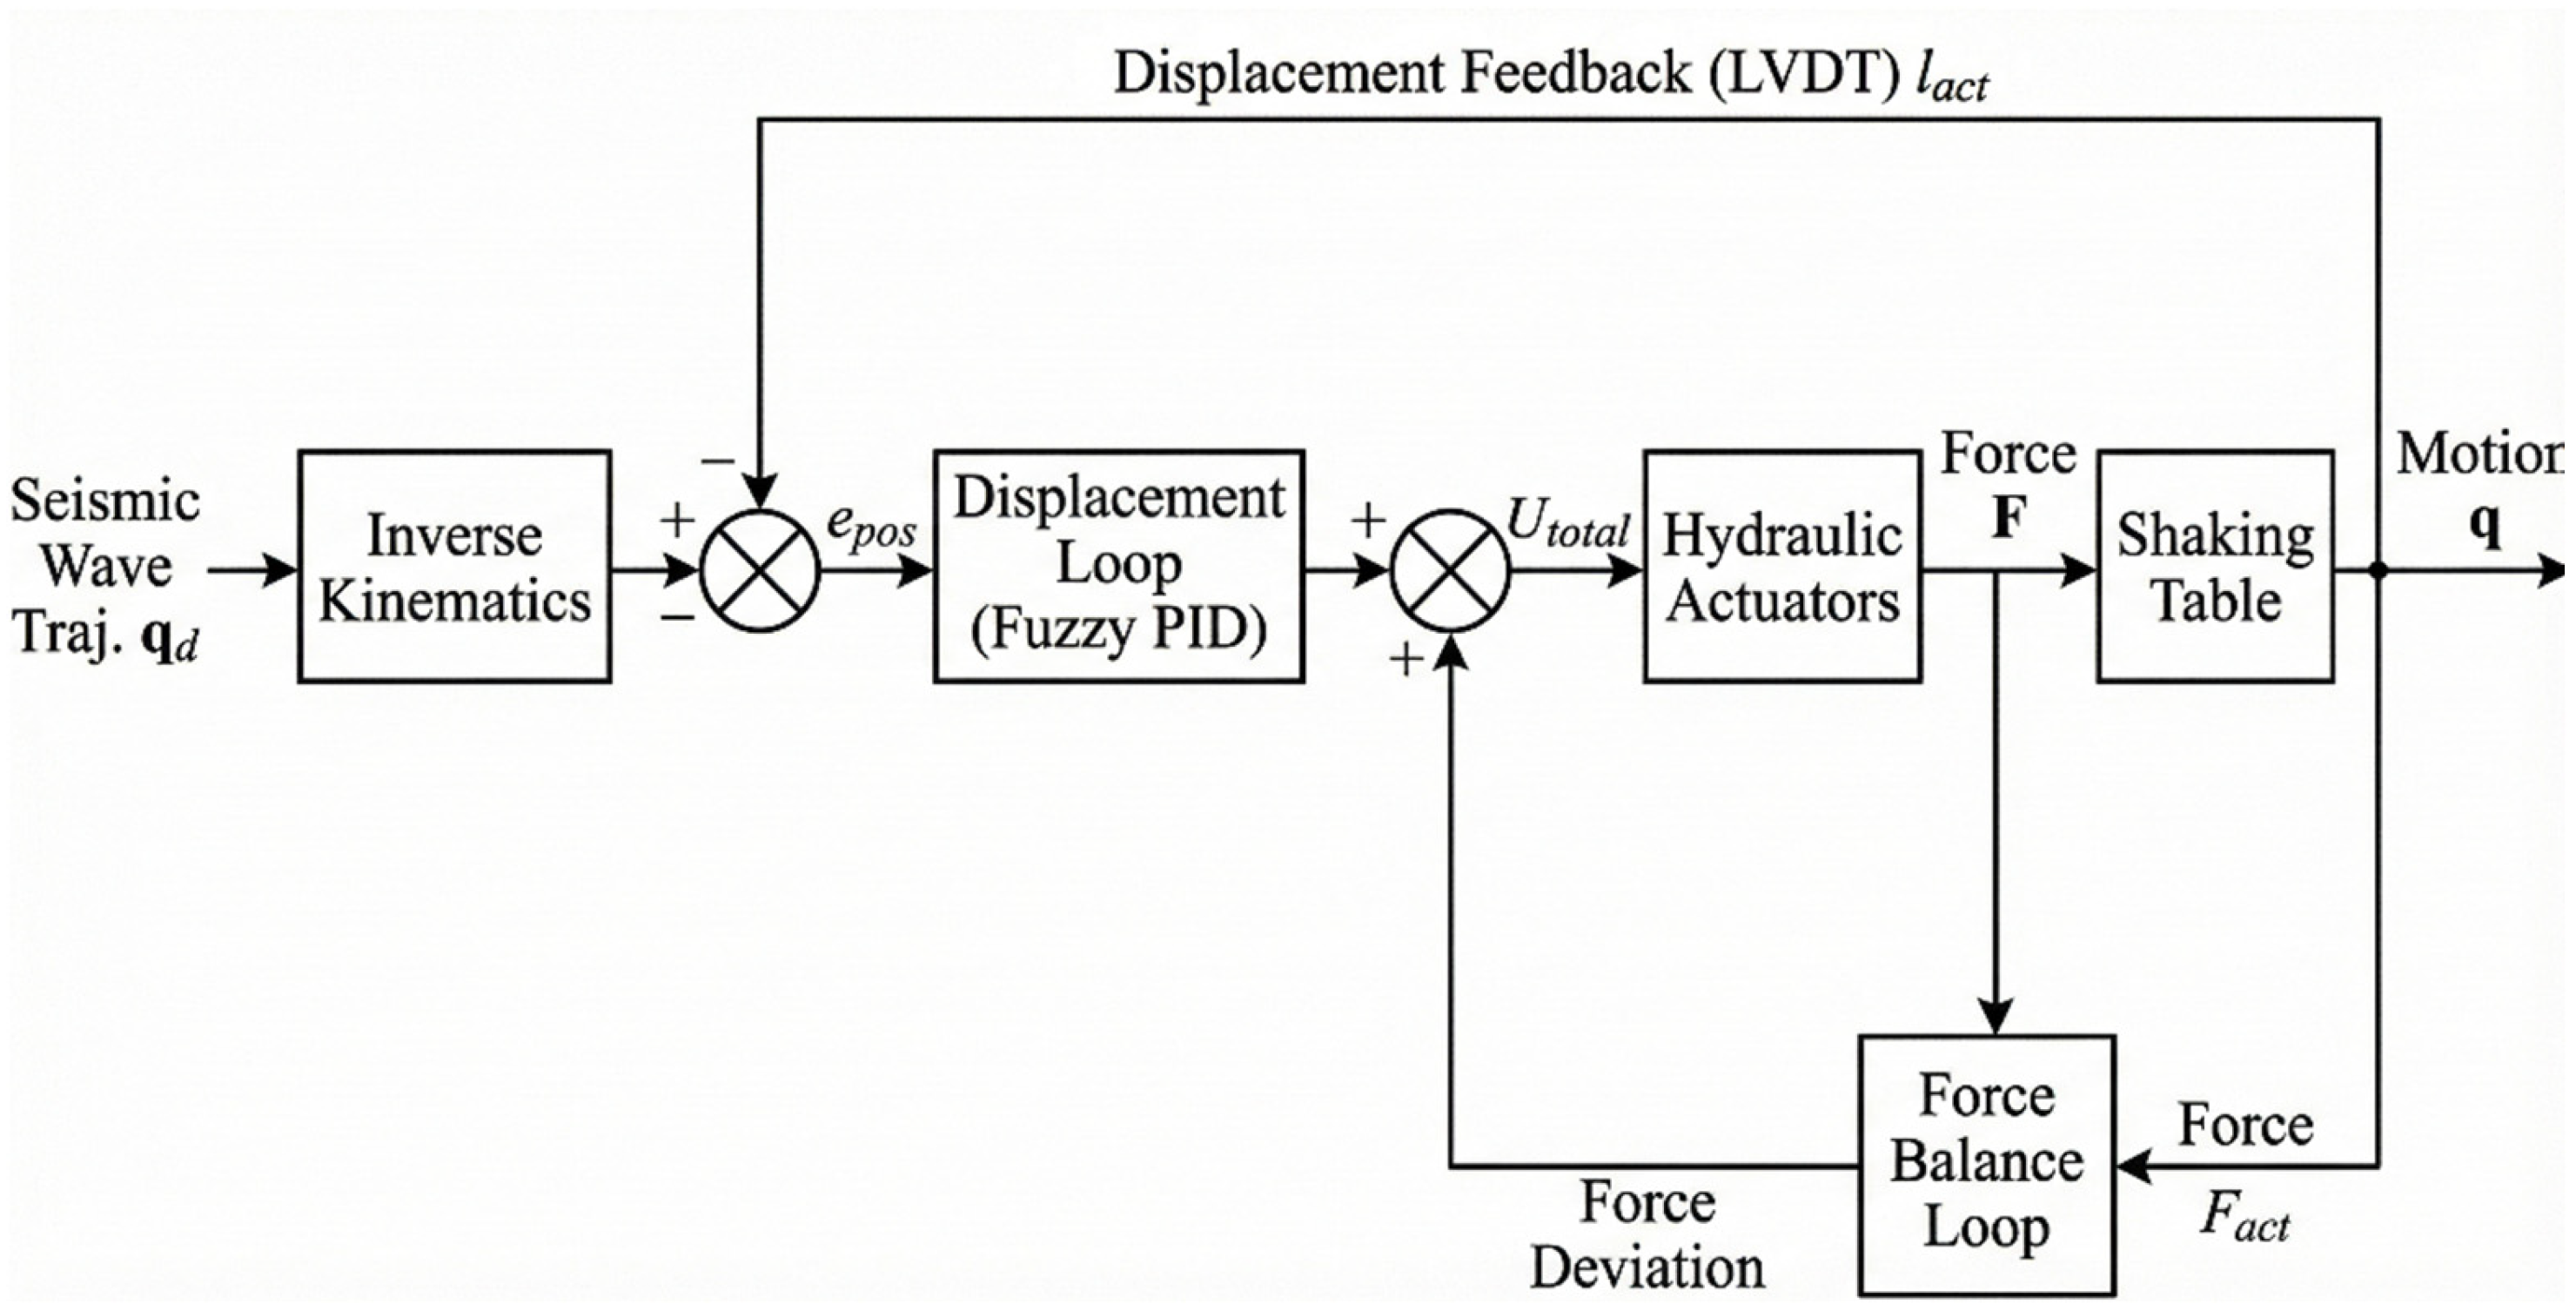
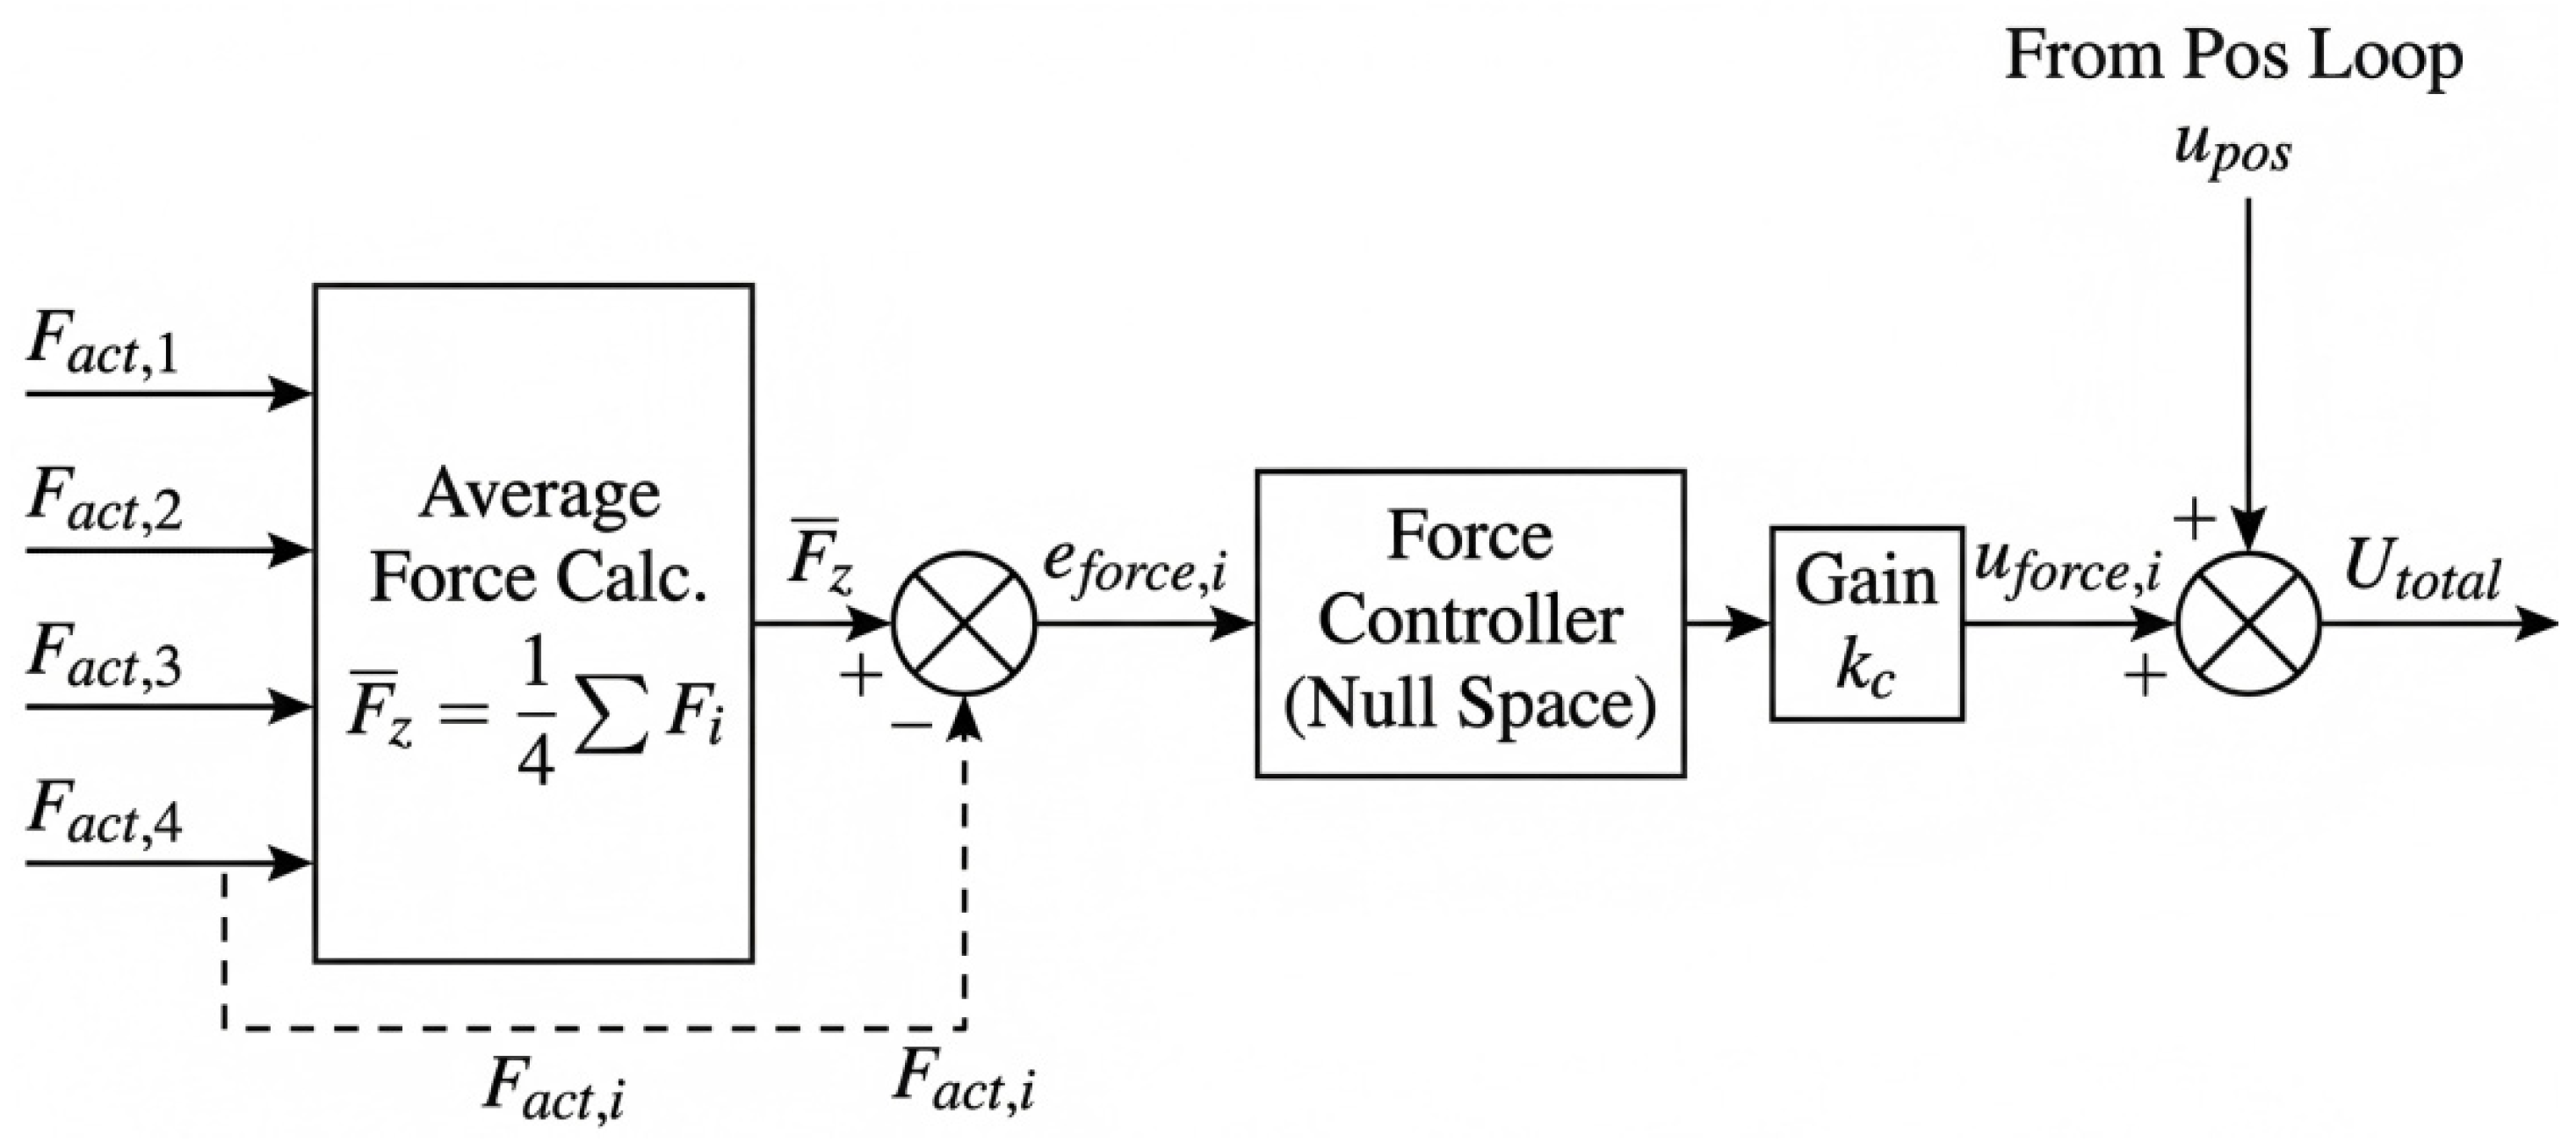
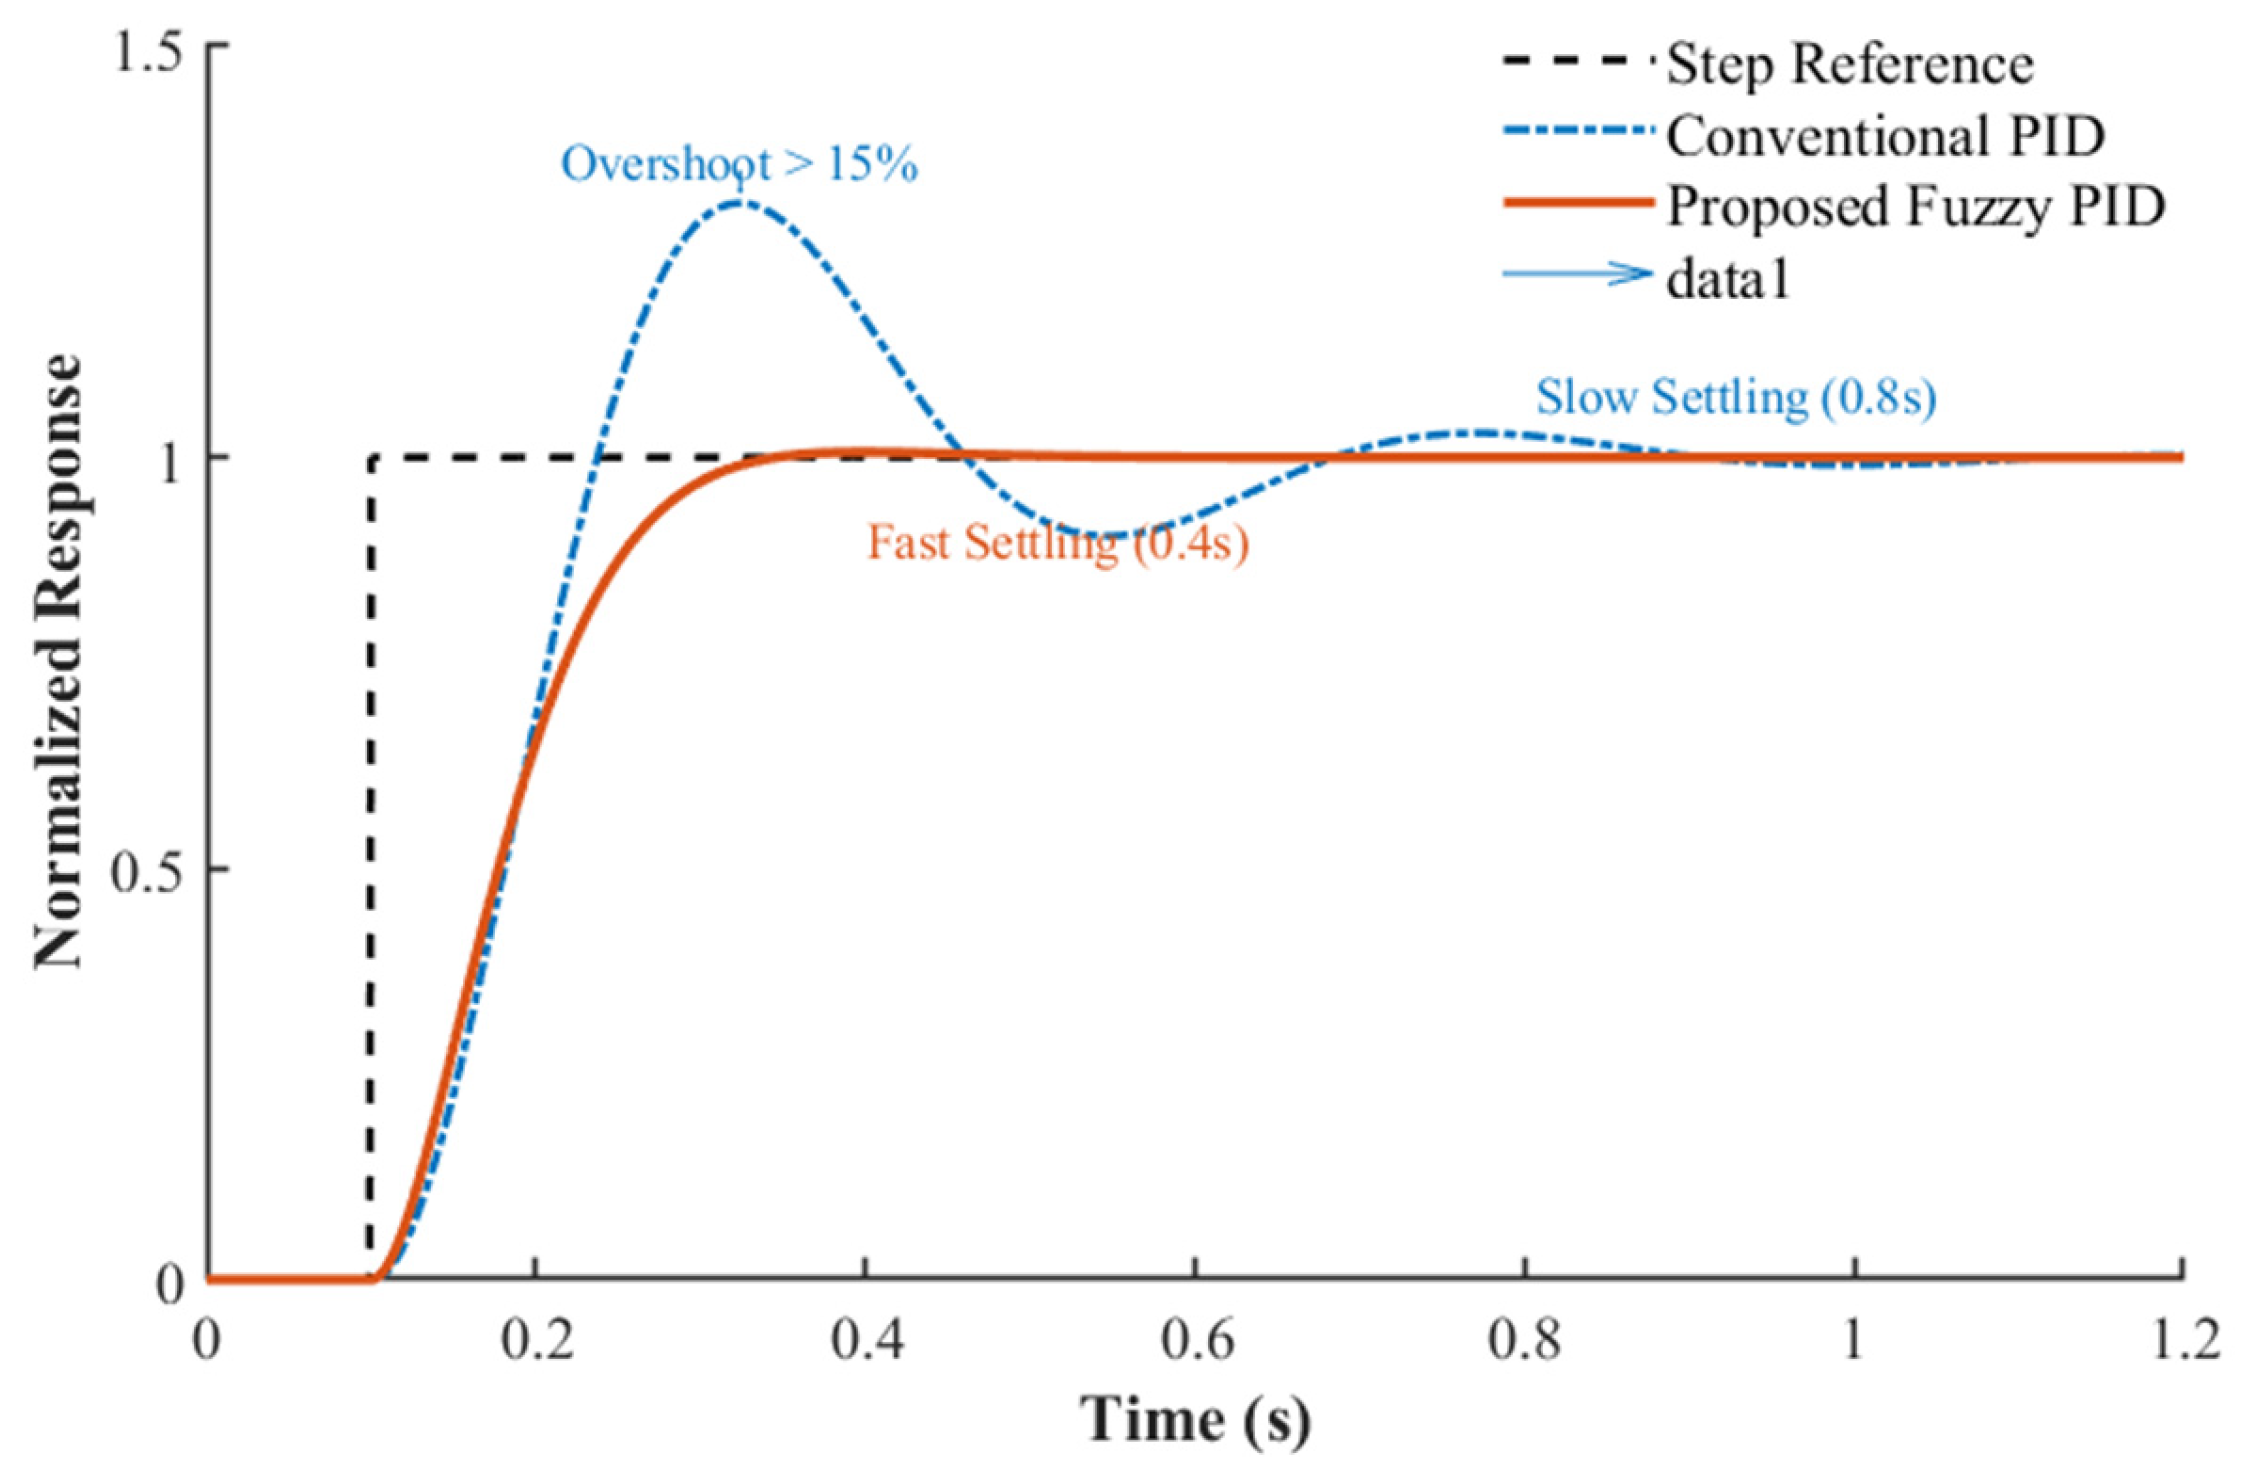
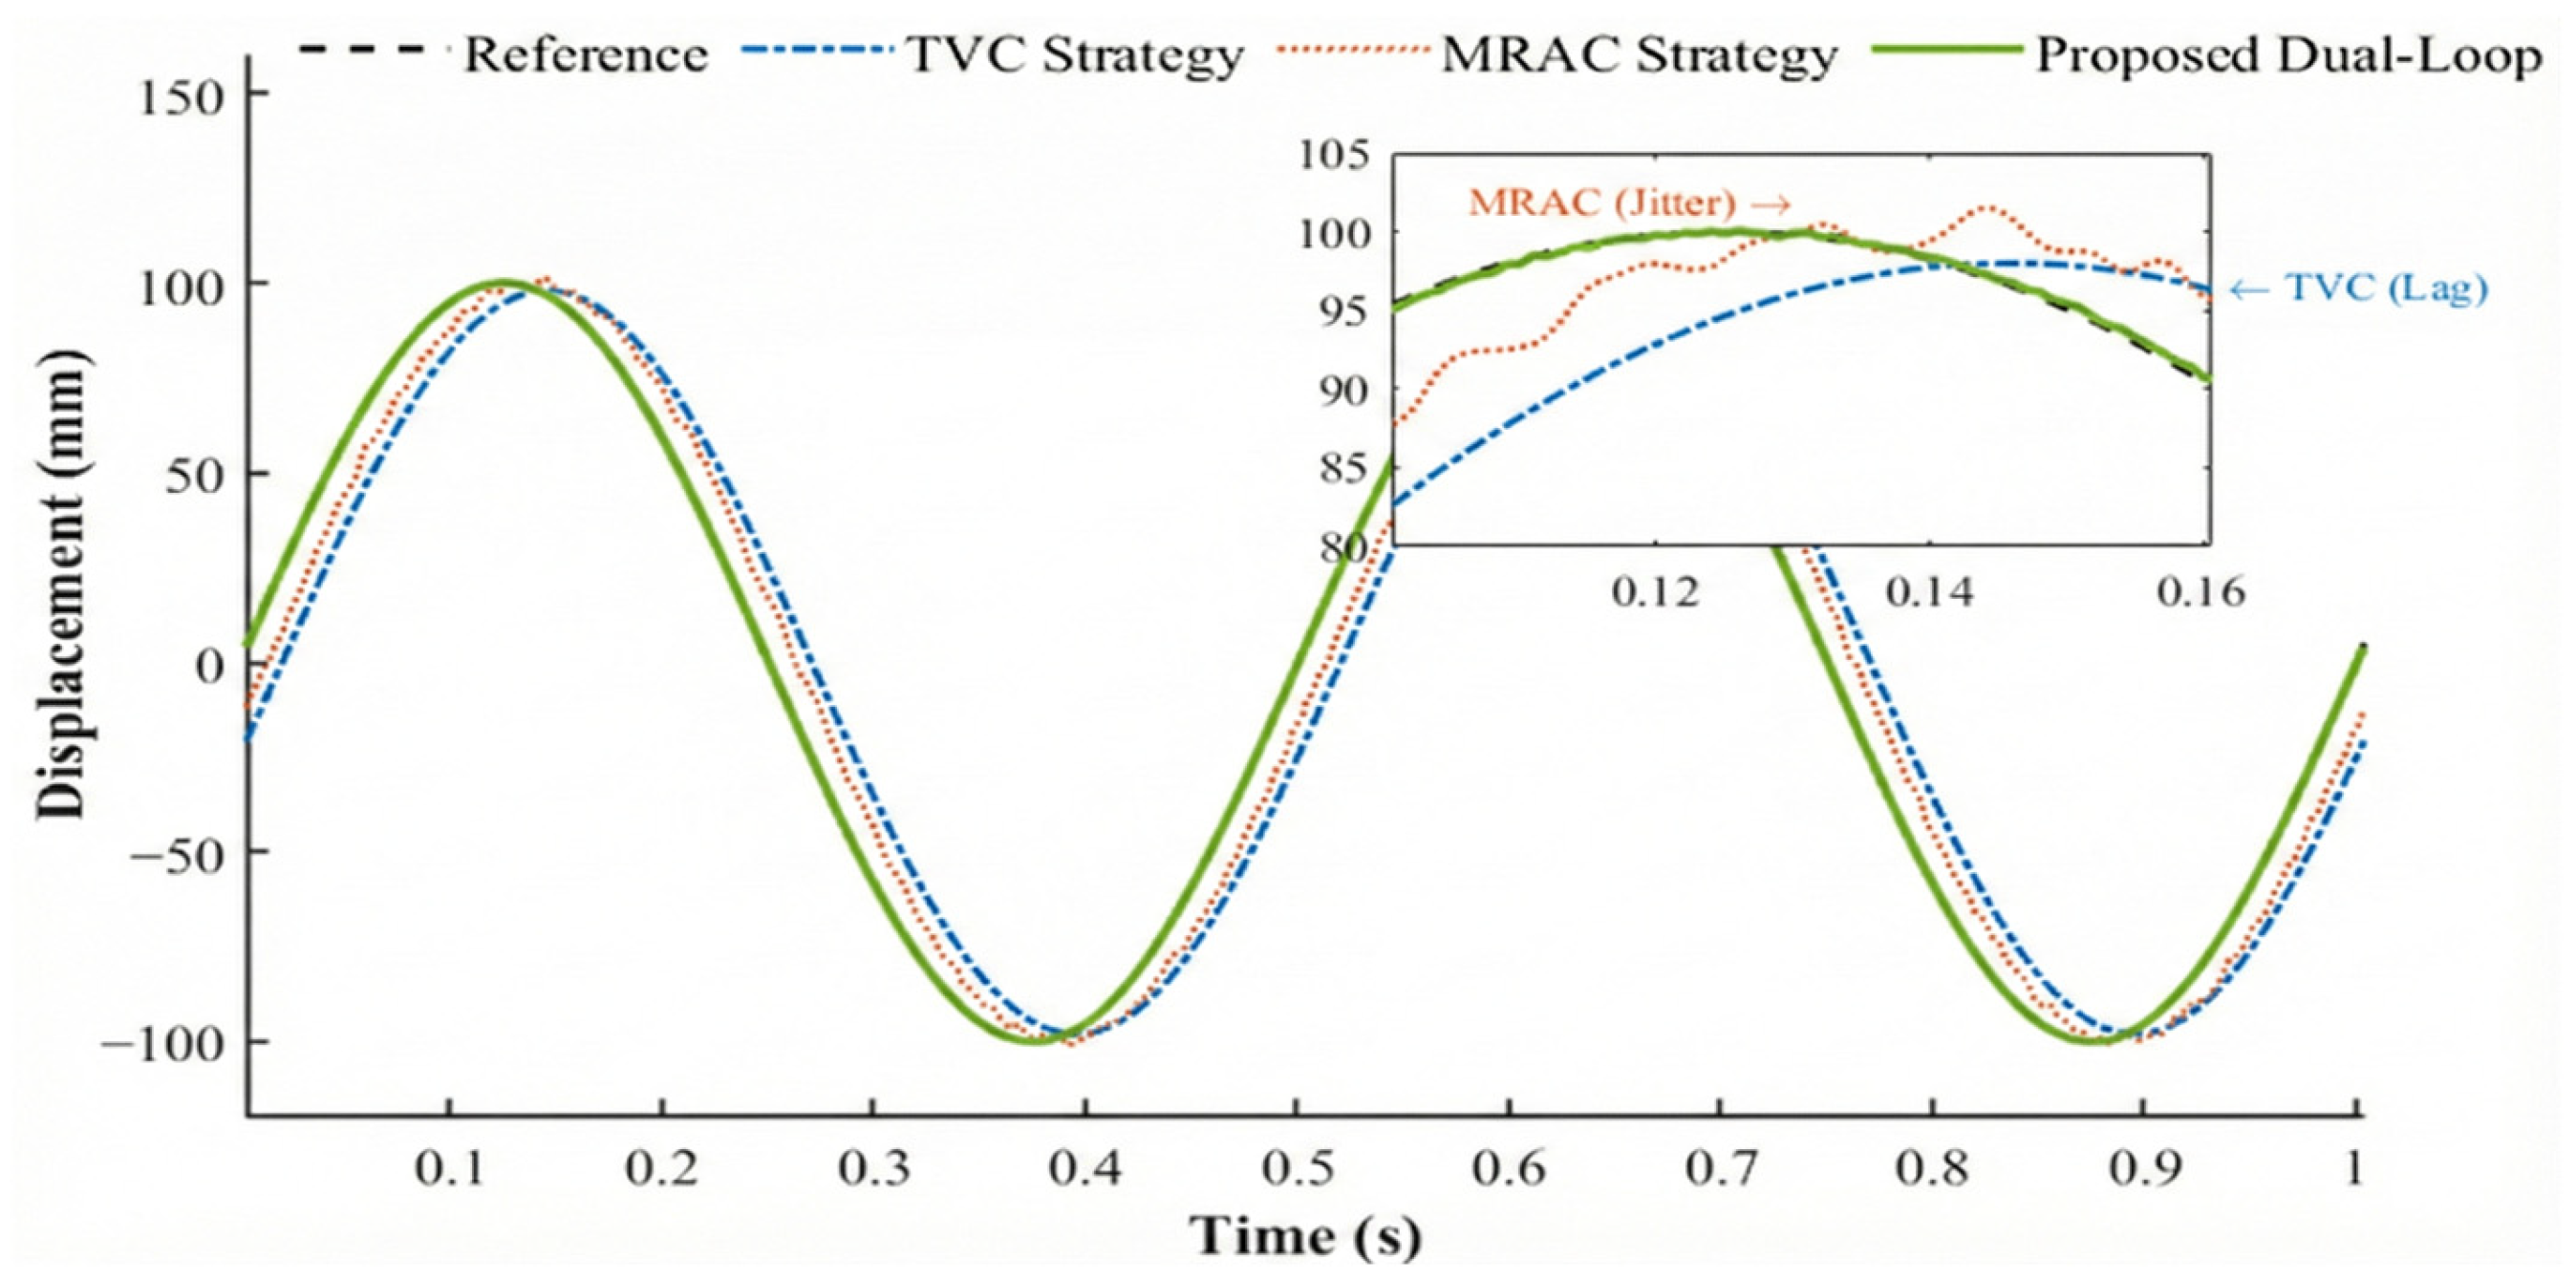
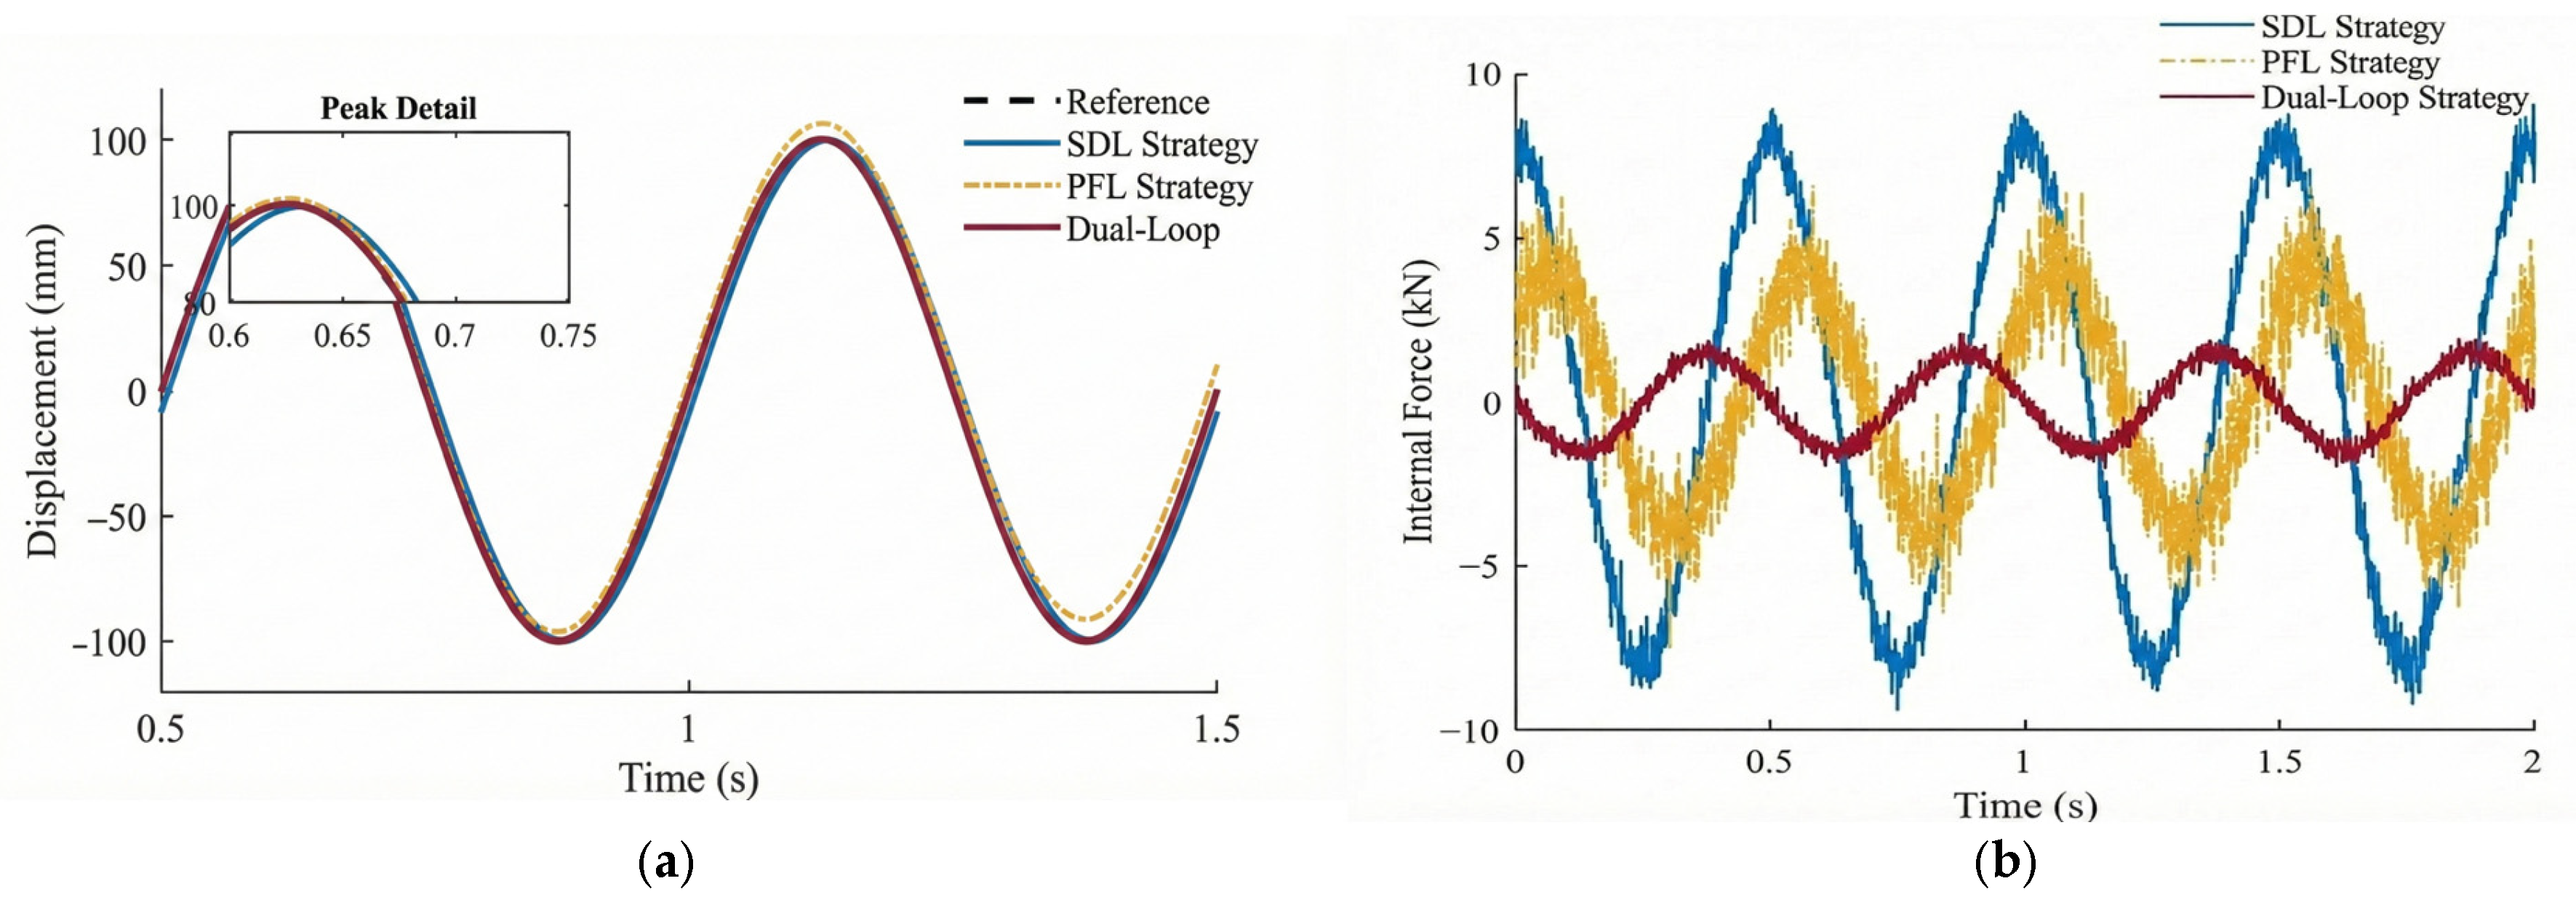
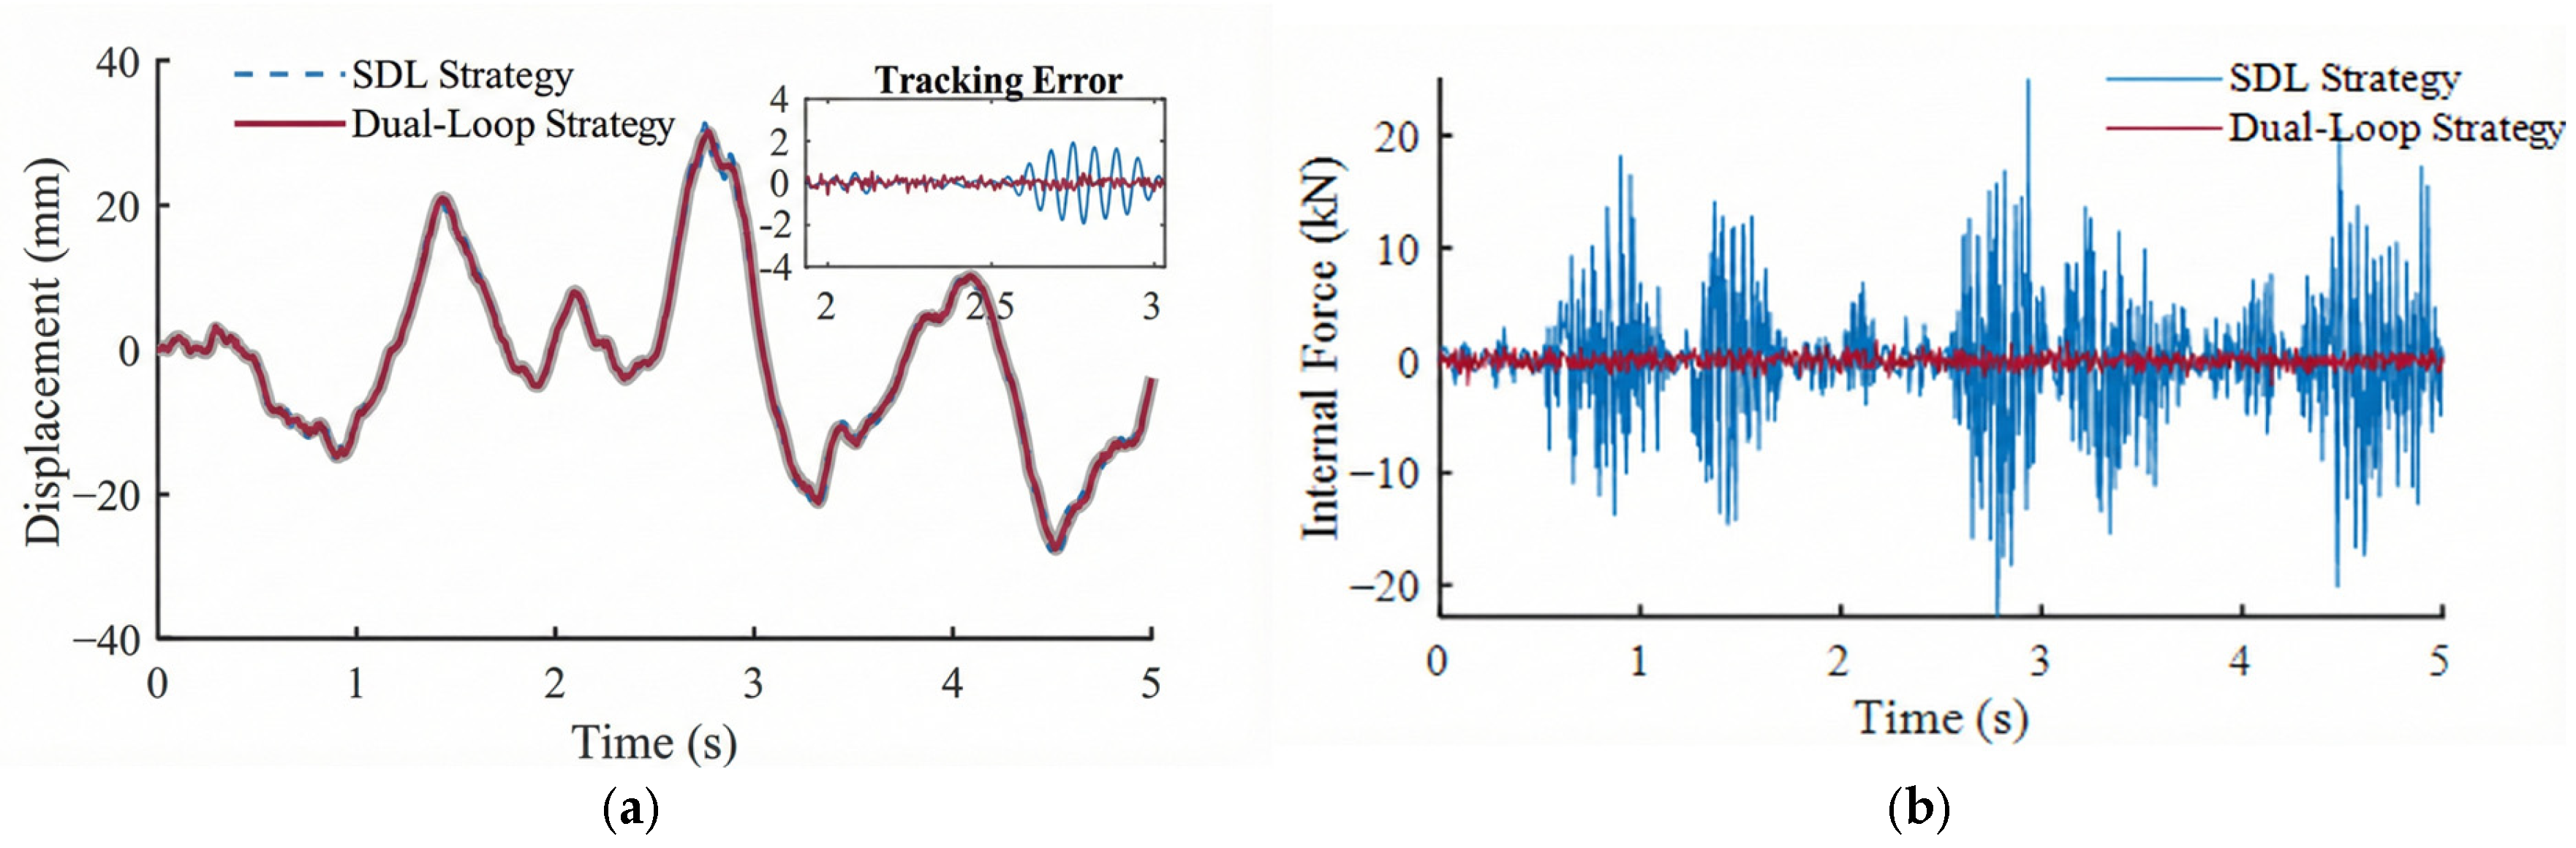
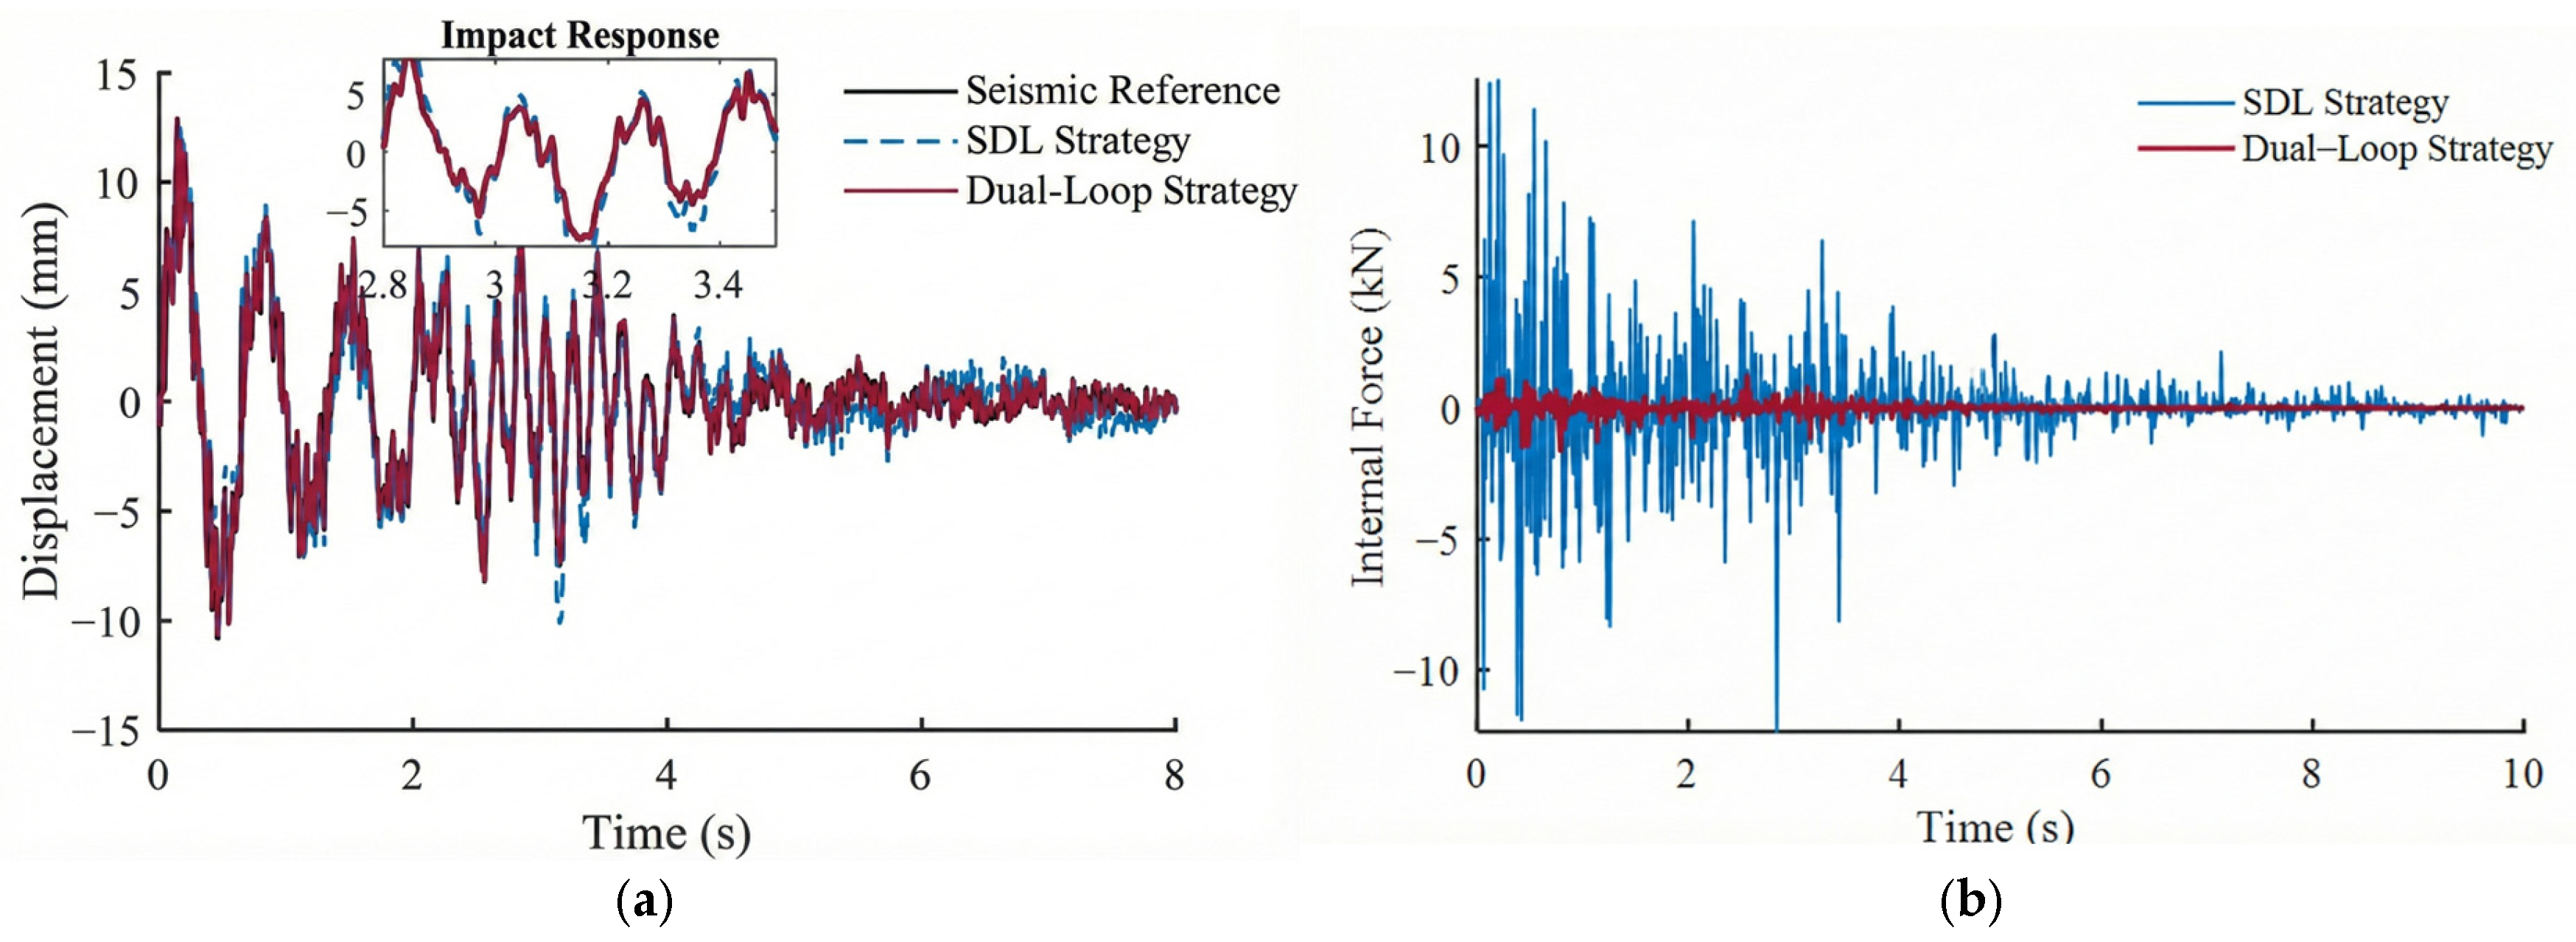
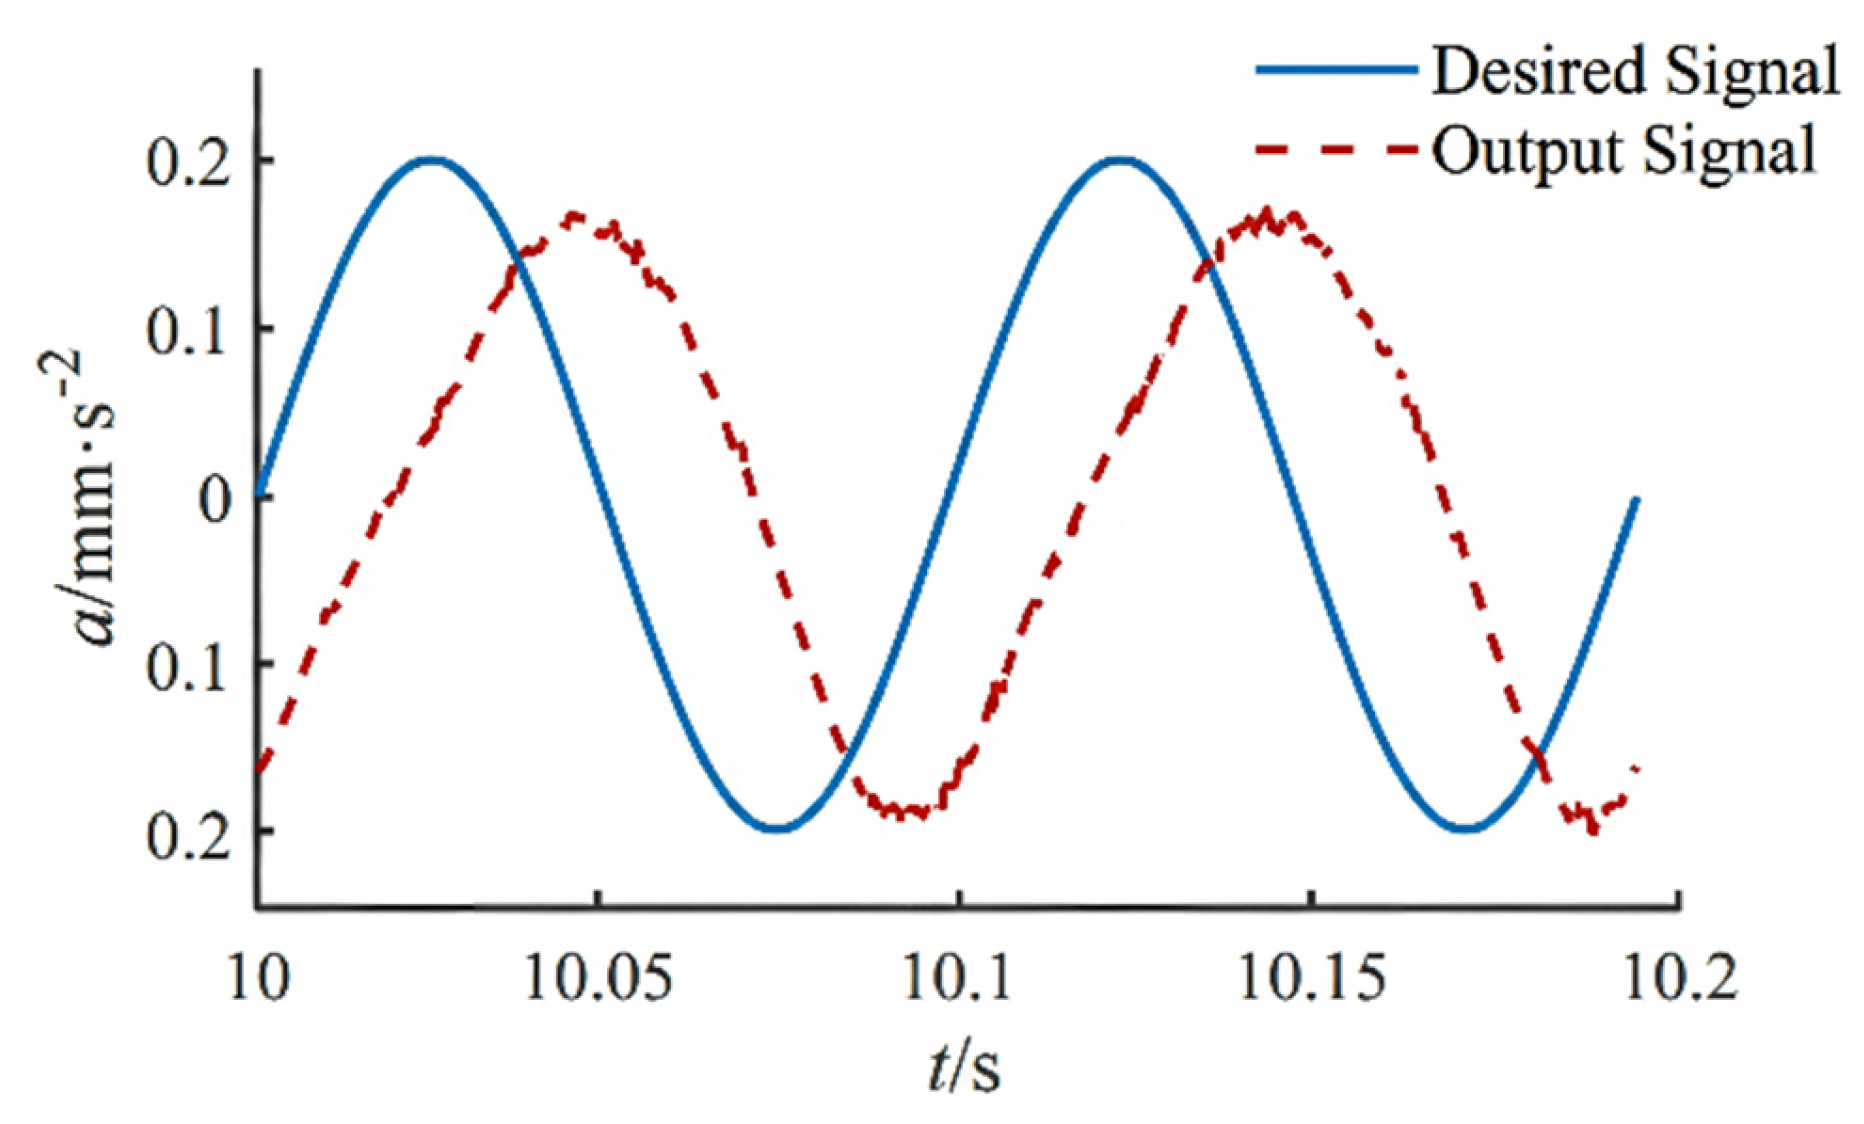
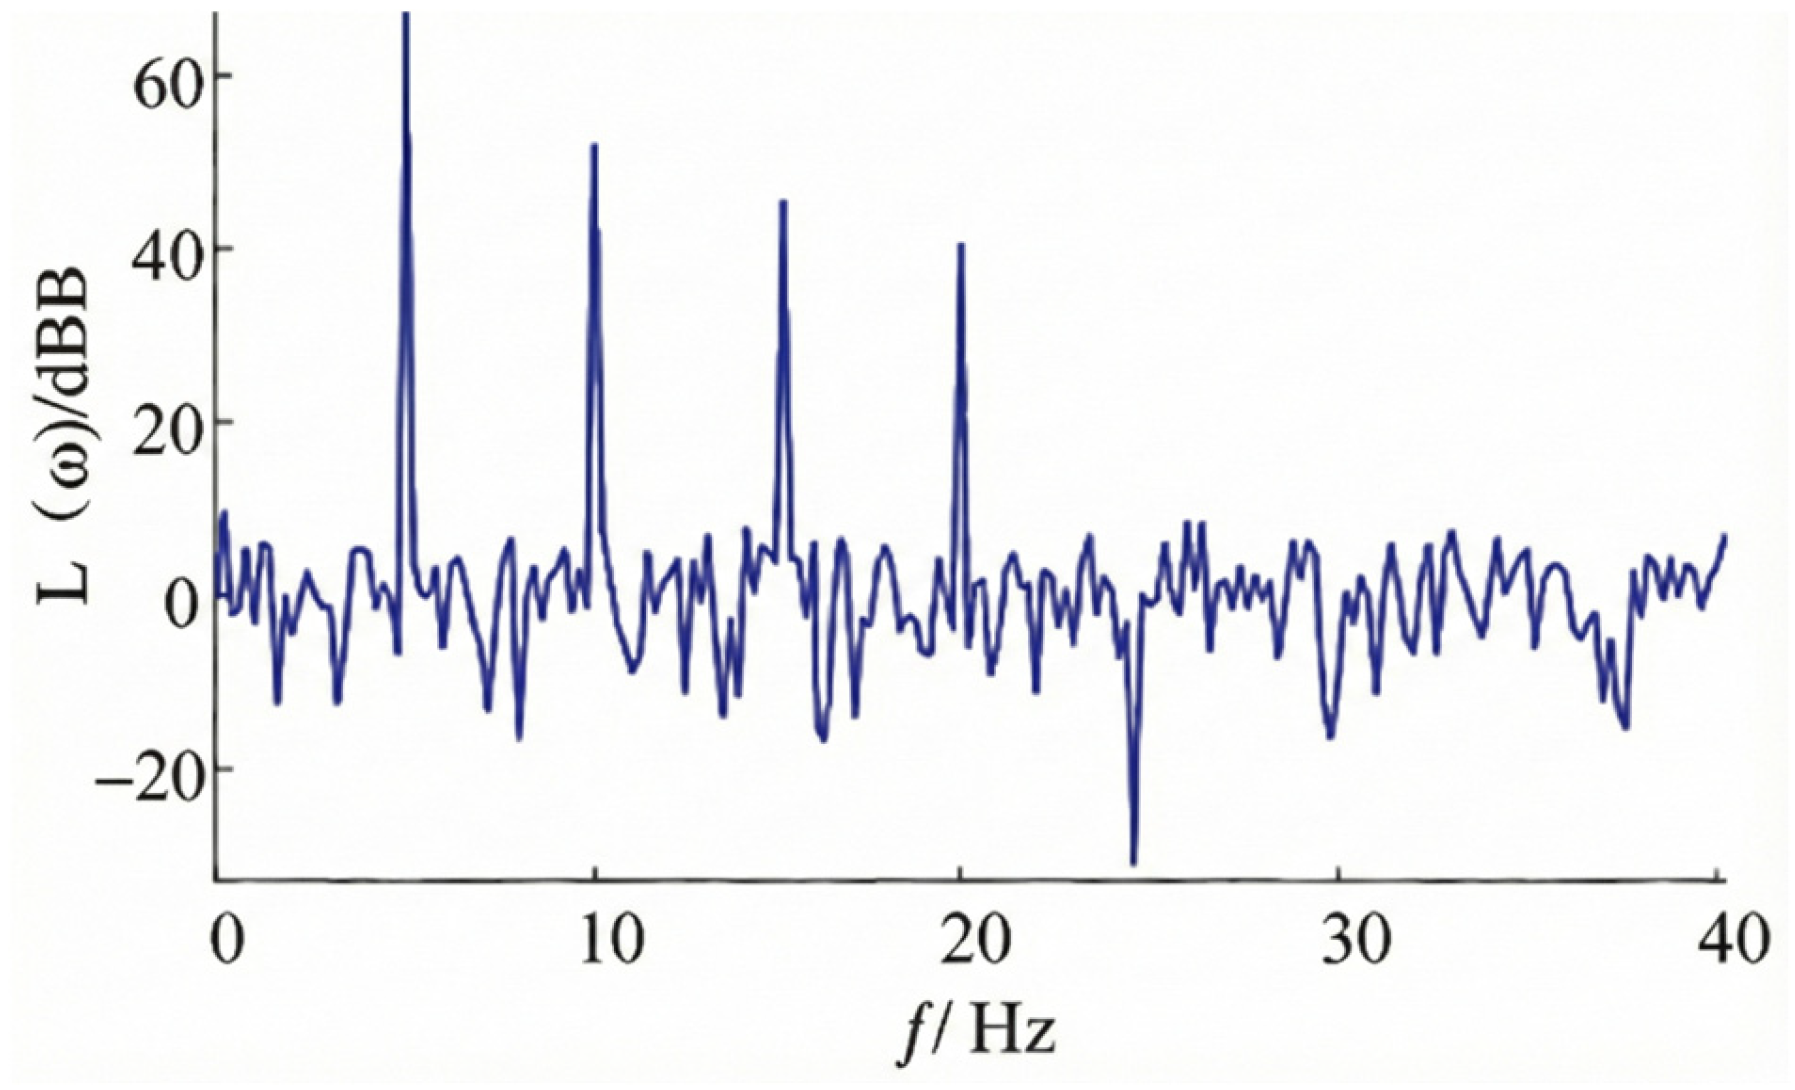
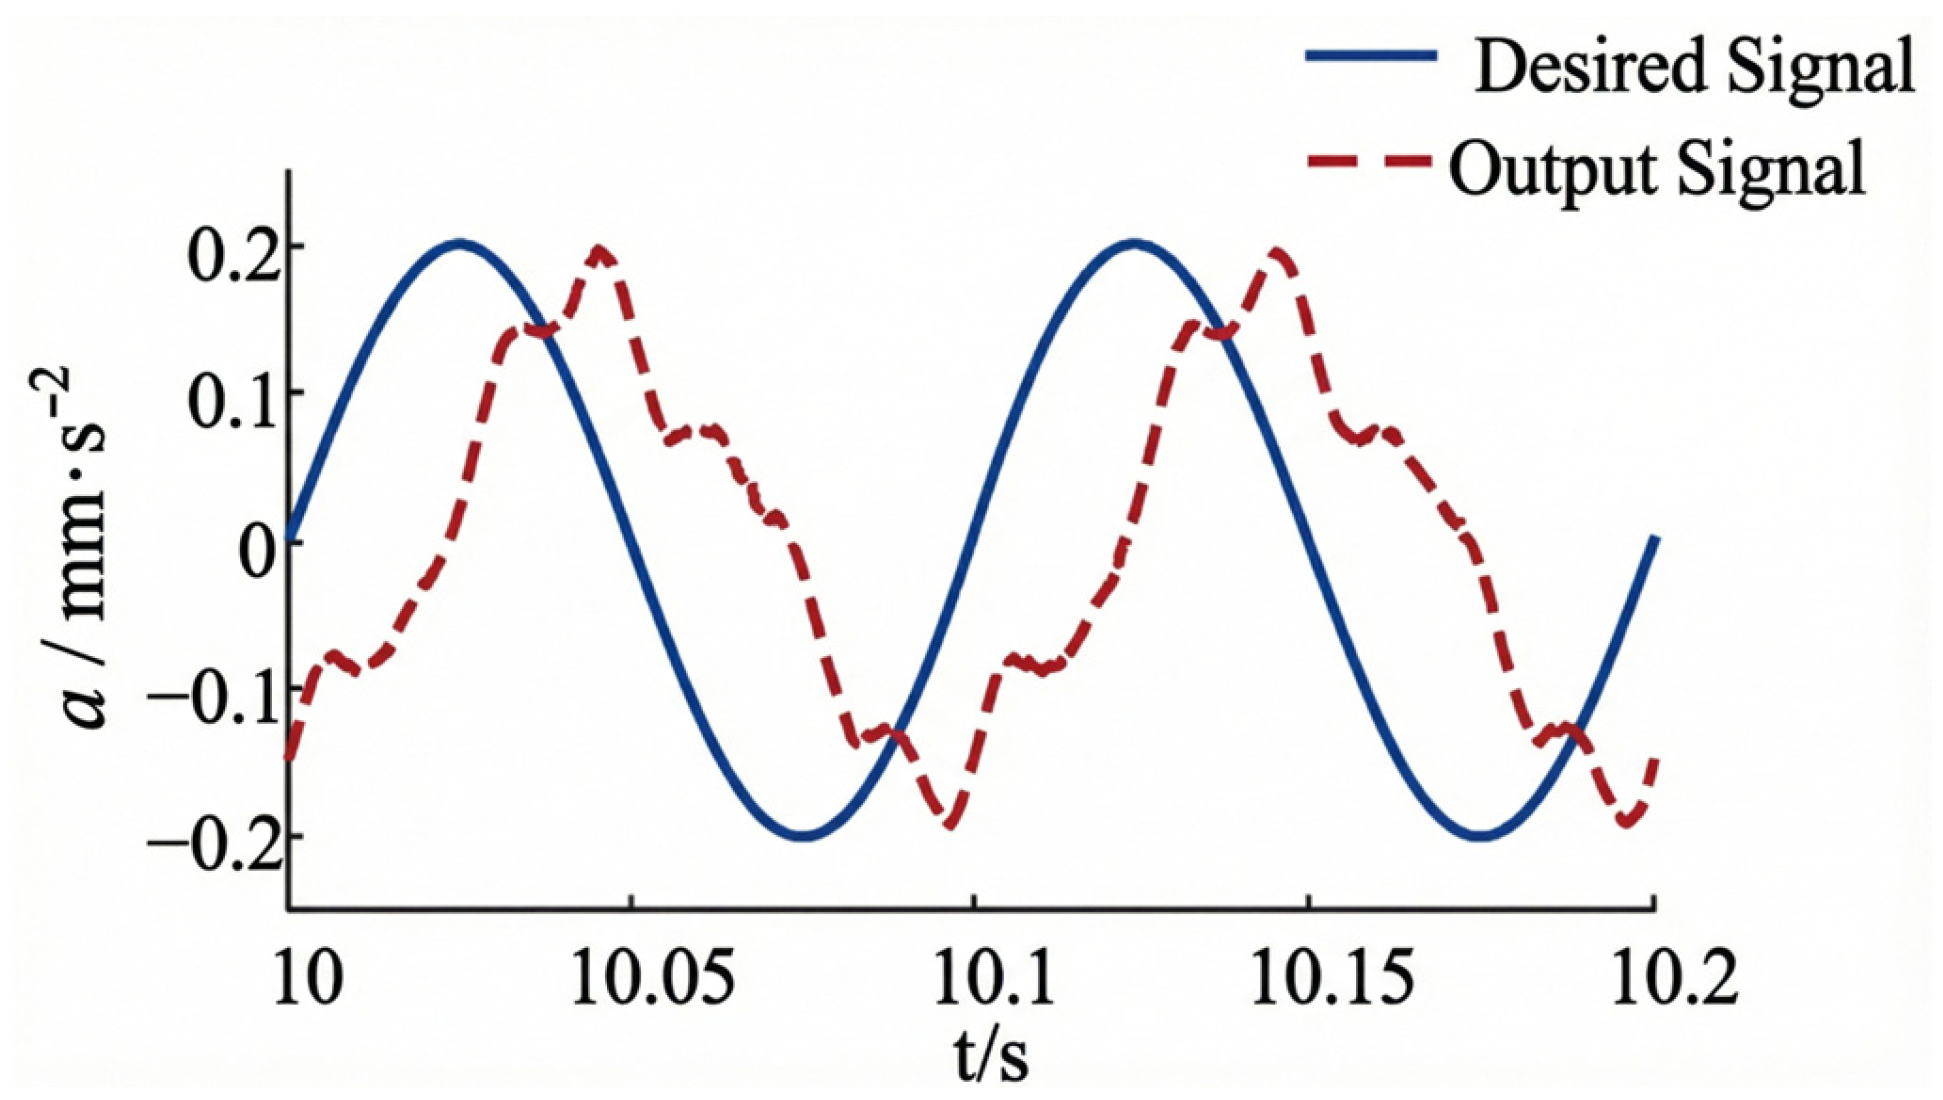
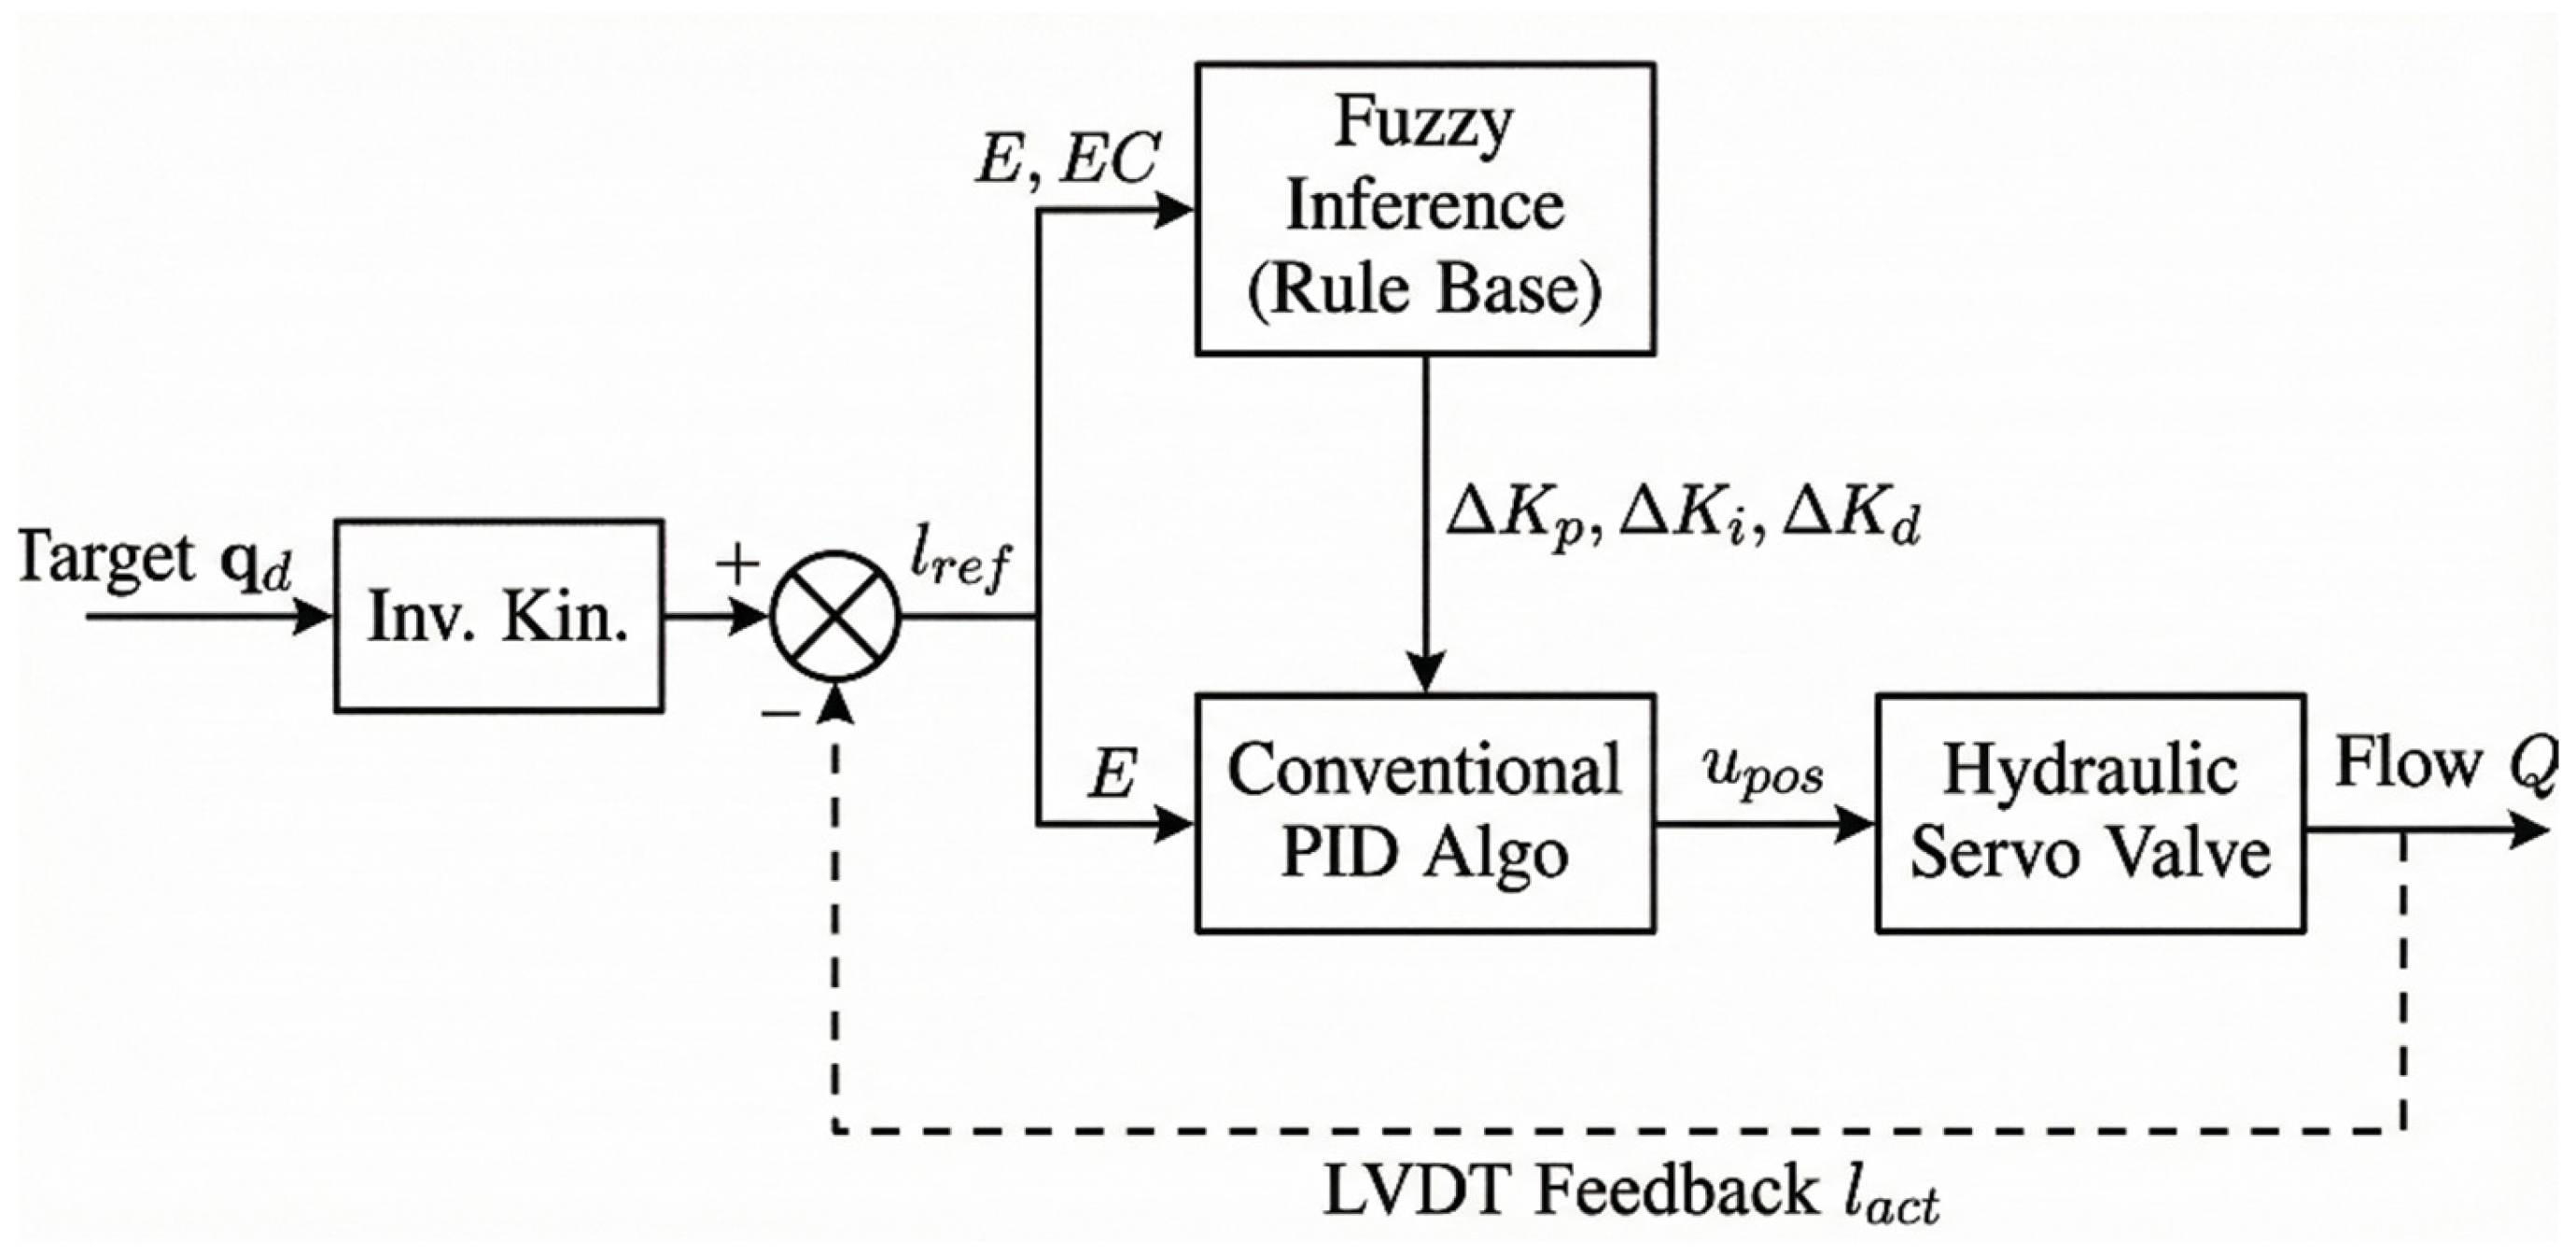
The vertical actuation of multi-axis seismic simulators usually requires a redundant parallel scheme for high load capacity. Due to geometric over-constraints, the internal force coupling and the nonlinear hysteresis are high; thus, waveform reproduction quality and structural fatigue may result. A displacement–force dual closed loop cooperative control mechanism can address these problems. First, a real-time kinematic model is developed to overcome the platform pose via actuator extension, and second, a dynamic force balance loop is introduced to actively redistribute the load components. In addition, a fuzzy PID controller is incorporated to optimize gain scheduling online, compensating for hydraulic nonlinearities and time-varying structural parameters. In the experiment on a 3 × 3 m 6-DOF shaking table, the presented method performs very favorably compared to traditional methods. Under broadband random excitation, the THD of acceleration waveform drops from 15.2% (single-loop control) to 3.2%, and the internal momentum oscillation amplitude is suppressed by over 70%. The results show that our proposed method eliminates internal force dependence while maintaining high precision trajectory tracking for seismic simulation.
Keywords: hydraulic shaking table; redundant parallel mechanism; internal force coupling; fuzzy PID control; waveform fidelity; dual-loop control hydraulic shaking table; redundant parallel mechanism; internal force coupling; fuzzy PID control; waveform fidelity; dual-loop control