Article

Smartphone-Based Estimation of Ground Reaction Forces and Lower-Limb Kinematics During Functional Tasks Using OpenCap: A Feasibility Study

by
Ranieri Santanchè
1,
Antonia Centrone
1,*,
Francesca Di Puccio
1,2 and
Lorenza Mattei
1,2
1
Department of Civil and Industrial Engineering, University of Pisa, 56126 Pisa, Italy
2
Rehab and Sport Centre, University of Pisa, 56121 Pisa, Italy
*
Author to whom correspondence should be addressed.
Appl. Sci. 2026, 16(18), 9211; https://doi.org/10.3390/app16189211
Submission received: 7 August 2026 / Revised: 10 September 2026 / Accepted: 15 September 2026 / Published: 17 September 2026

Featured Application

This work explores the technical feasibility of smartphone-based markerless motion capture for estimating lower-limb kinematics and ground reaction forces during functional movements. In a single healthy participant, the approach reproduced selected movement patterns and resultant loading profiles, while variable-dependent discrepancies and task-specific processing requirements were also identified. These findings support further investigation of smartphone-based biomechanics for research and field-oriented applications, while larger validation studies are required before individual-level clinical use can be considered.

Abstract

(1) Background: Markerless motion capture may enable scalable biomechanical assessment outside laboratory environments, yet its applicability to tasks involving elevated foot contacts and rapid loading transitions remains insufficiently characterized. This feasibility study evaluated OpenCap, an open-source smartphone-based markerless system, for estimating lower-limb kinematics and ground reaction forces during stair ascent, stair descent, squat, sit-to-stand, and forward lunge. (2) Methods: One healthy adult completed three repetitions of each task while data were acquired simultaneously with three smartphones, an eight-camera Vicon system, and two force plates. OpenCap/OpenSim outputs were adapted for stair and lunge kinetics and compared with marker-based kinematics and force-plate measurements using root mean square error, Pearson correlation, and cosine similarity. (3) Results: Agreement was strongest for sagittal-plane lower-limb kinematics, particularly knee flexion-extension (RMSE: 1.4–10.5 deg; Pearson: 0.94–0.999). Larger discrepancies occurred for hip internal-external rotation, pelvis motion during sit-to-stand, and ankle flexion-extension. Resultant GRF waveforms showed high similarity to force-plate data (cosine similarity ≥ 0.988; RMSE: 0.069–0.167 BW). Stair descent produced the largest deviations and variability, particularly for single-limb forces. (4) Conclusions: In this feasibility study, smartphone-based markerless analysis agreed best with laboratory measurements for sagittal lower-limb kinematics and resultant GRF waveforms but showed larger discrepancies in multiplanar kinematics and limb-specific loading. The adapted pipeline is technically feasible for exploratory movement analysis, although larger, repeated-session studies are needed before clinical use.

1. Introduction

Markerless motion capture systems are increasingly used for biomechanical assessment because they reduce setup time, hardware requirements, and operator dependency, compared with conventional marker-based motion capture, facilitating movement analysis beyond specialized laboratory environments [1,2,3,4]. Recent advances in computer vision have enabled human pose and three-dimensional movement to be reconstructed from standard video recordings, increasing the accessibility and portability of quantitative movement analysis. Smartphone-based approaches are attractive because of the widespread availability, relatively low cost, and portability of consumer devices, with potential applications in clinical, sports, field, and remote assessment settings [5]. Among them, OpenCap is particularly relevant because it integrates multi-view smartphone video acquisition and pose estimation with musculoskeletal modeling in OpenSim [6], one of the most widely adopted open-source platforms for biomechanical modeling and simulation. By combining accessible markerless data acquisition with OpenSim’s established capabilities for anatomically constrained movement analysis, OpenCap substantially reduces the technological and logistical barriers to quantitative biomechanical assessment outside specialized laboratories. The seminal paper introducing OpenCap validated lower-limb kinematics across multiple degrees of freedom during movements including walking, squatting, sit-to-stand, and drop jumping [6]. Subsequent studies have extended its evaluation to a broader range of functional and sport-related movements, including squatting, hopping, jumping, side-stepping, and return-to-sport tasks [7,8,9], as well as gait in healthy and pathological populations [10].
However, agreement with laboratory-based evaluations varies according to the task, joint, and degrees of freedom analyzed. Sagittal-plane variables generally show more consistent agreement, whereas larger or more variable discrepancies have been reported for some frontal- and transverse-plane variables [6,7,8,9,10]. Repeatability and acquisition-related factors, such as clothing, have also been investigated [11]. Overall, the available evidence indicates that OpenCap can reproduce several clinically and functionally relevant features of lower-limb motion, while also showing that its performance is task- and variable-dependent. Although its kinematic performance has been investigated across several functional and sport-related movements, evidence remains comparatively limited for tasks involving elevated or asymmetric support conditions, such as stair negotiation and forward lunges. Assessing these movements may therefore provide further insight into the performance of smartphone-based markerless kinematics under functional conditions that differ from those most investigated.
Beyond kinematic analysis, estimating kinetic variables—particularly ground reaction forces (GRFs)—remains a major challenge in markerless biomechanics, as it requires an additional modeling or inference step. In OpenCap, smartphone-derived kinematics are tracked through physics-based musculoskeletal simulations, with foot–ground interactions represented by compliant Hunt–Crossley contact elements, thus enabling GRF estimation without force-plate measurements during data acquisition [6].
Previous studies reported promising OpenCap-based GRF estimation during gait and jumping tasks [12,13]. However, direct, synchronized comparisons between OpenCap-estimated GRFs and force-plate measurements during stair negotiation and forward lunge remain limited. These tasks introduce additional challenges for physics-based kinetic estimation because they involve elevated or asymmetric foot contacts, transitions between support conditions, and rapid changes in loading. Moreover, their analysis may require adaptations to the standard kinetics workflow to account for task-specific foot-ground interactions.
Accordingly, the aim of this feasibility study was to characterize the technical performance of the OpenCap/OpenSim pipeline for estimating lower-limb kinematics and GRFs during stair ascent, stair descent, squat, sit-to-stand, and forward lunge. OpenCap outputs were compared with simultaneously acquired marker-based kinematics and force-plate measurements to characterize waveform agreement and identify task- and variable-specific discrepancies.
The main contributions of this study are: (i) a simultaneous comparison of OpenCap-derived kinematics with marker-based measurements across five functional tasks; (ii) a direct, synchronized comparison of OpenCap-estimated and force-plate-measured GRFs during tasks including stair negotiation and forward lunge; and (iii) the identification and implementation of task-specific adaptations to the OpenCap/OpenSim kinetics workflow for elevated foot-contact conditions. Flexion-extension represents the dominant component of lower-limb motion during several of the investigated tasks; therefore, sagittal-plane agreement provides a first indication of the ability of the markerless workflow to reproduce their principal movement patterns.
Rather than providing population-level validation, this study is intended to establish technical feasibility and identify methodological limitations and processing requirements that should be addressed in subsequent larger-scale validation studies.

2. Materials and Methods

2.1. Participant and Functional Tasks

One healthy adult male participant (29 years old; body mass: 76 kg; height: 1.75 m; body mass index (BMI, calculated as body mass in kilograms divided by the square of height in meters): 24.8 kg/m2) with no history of musculoskeletal injuries was enrolled in this feasibility study. The participant provided written informed consent before data collection and for the use of anonymized data for research dissemination. The single-participant design was intended to characterize the technical behavior of the OpenCap/OpenSim pipeline and identify task-specific processing requirements before larger-scale validation. Five functional tasks were analyzed: stair ascent (STA), stair descent (STD), squat (SQU), sit-to-stand (STS), and forward lunge (FWL). Each task was repeated three times at a self-selected speed, with the participant instructed to maintain a consistent movement speed across repetitions. For STA, the participant walked forward and stepped with the right dominant limb onto a 22 cm-high box positioned on the distal force plate before continuing the movement. For STD, the participant started on the elevated box and descended with the right dominant limb onto the force plate before resuming forward walking. During SQU, the participant was instructed to perform a squat to his maximum self-selected depth, with the feet shoulder-width apart, while maintaining heel contact with the ground; no external target or predefined joint-angle criterion was used to standardize squat depth. During STS, the participant stood up from a 45 cm-high stool without upper-limb assistance. For FWL, the participant performed a forward lunge with the right dominant limb onto the proximal force plate while keeping the hands on the hips.
Before each acquisition, a synchronization gesture recommended by the OpenCap protocol was performed to facilitate temporal alignment between smartphone videos.

2.2. Experimental Setup

2.2.1. OpenCap System

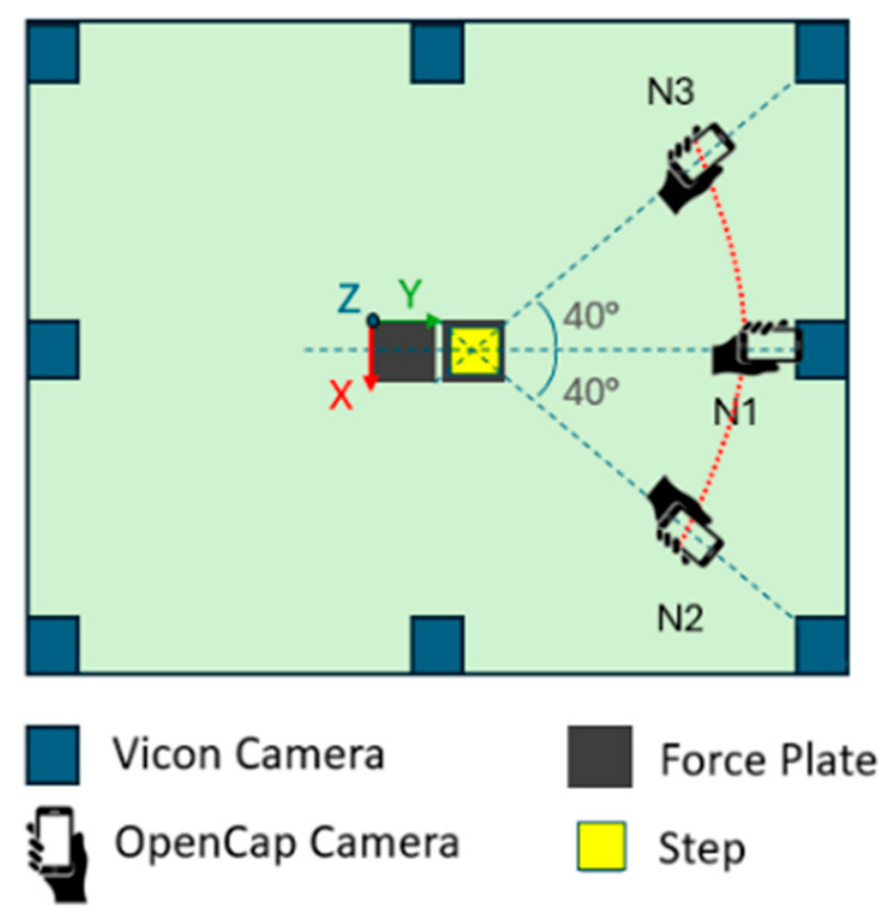
Three iPhone 12 devices (Apple Inc., Cupertino, CA, USA) were used for data acquisition. Videos were recorded at 120 fps with a resolution of 720 × 1280 pixels. The smartphones were mounted on tripods at a height of approximately 1.60 m and positioned 3–4 m from the participant’s starting position. The cameras were arranged to maximize capture volume and minimize body-segment occlusions. One camera was positioned in front of the participant, while the remaining two were placed at oblique angles of approximately 40° relative to the calibration checkerboard (Figure 1). Camera calibration was performed using the standard OpenCap checkerboard (4 × 5 grid, 35 mm squares) positioned perpendicular to the ground. Videos were processed through the OpenCap cloud-based pipeline (https://app.opencap.ai (accessed on 3 August 2026)), which automatically generated three-dimensional virtual marker trajectories from synchronized smartphone recordings.

2.2.2. Marker-Based Motion Capture System

Marker-based motion capture data were simultaneously acquired using an eight-camera Vicon system (Vicon Motion Systems Ltd., Oxford, UK) operating at 120 Hz. Ground reaction forces were synchronously recorded using two AMTI OR6-7-1000 force plates (AMTI, Watertown, MA, USA) sampled at 1000 Hz.

2.2.3. OpenCap Processing

Videos acquired with OpenCap were processed through the OpenCap cloud-based pipeline to generate three-dimensional virtual marker trajectories. Two-dimensional body keypoints were detected using the HRNet pose-estimation model and triangulated into three-dimensional space through Direct Linear Transformation. The resulting trajectories were subsequently mapped to anatomical virtual markers using a Long Short-Term Memory network trained on large-scale motion datasets to improve biomechanical consistency [6], as specified by the developers of OpenCap.
The generated marker trajectories (.trc files) were used as input for musculoskeletal analysis within OpenSim. Joint kinematics were estimated using the OpenCap automated inverse kinematics pipeline, adopting the Lai–Uhlrich full-body musculoskeletal model [14,15], comprising 22 body segments and 33 degrees of freedom.
Model scaling was performed from a static neutral pose acquired before the dynamic trials. During the calibration pose, the participant stood upright with feet shoulder-width apart and arms outstretched, slightly away from the body.
OpenCap estimates joint kinematics using a constrained inverse kinematics approach in which joint definitions and musculoskeletal geometry enforce biomechanically plausible motion. Consequently, the estimated kinematics depend on both model scaling quality and pose-estimation accuracy.

2.2.4. Marker-Based Processing

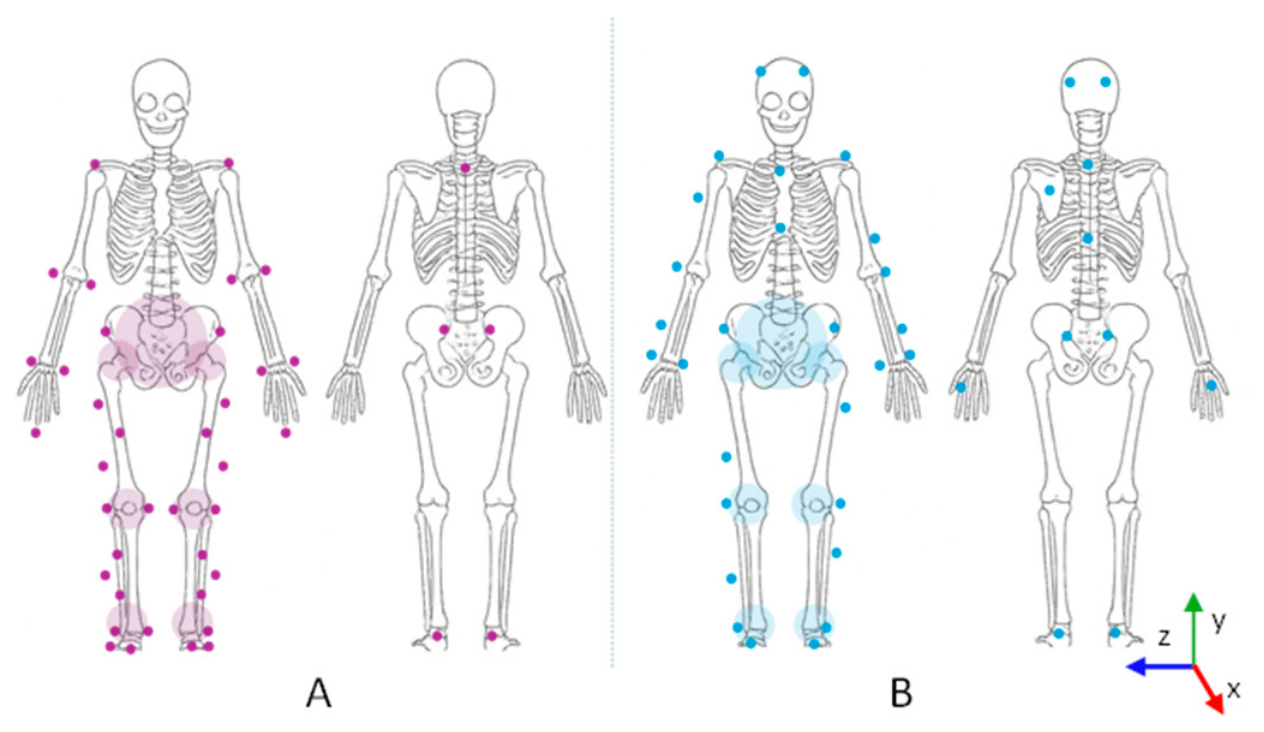
Marker-based motion capture data were processed in Vicon Nexus 2.16.1 (Vicon Motion Systems Ltd., Oxford, UK) using the Plug-In Gait (PiG) full-body model. The model included 39 reflective markers positioned on anatomical landmarks to reconstruct three-dimensional joint kinematics (Figure 2).
Unlike OpenCap/OpenSim, the PiG model estimates segment kinematics independently using an unconstrained kinematic framework. Pelvis orientation and lower-limb joint angles were extracted for subsequent comparison with OpenCap outputs.

2.2.5. Data Processing and Alignment

OpenCap joint-angle trajectories were filtered using a fourth-order low-pass Butterworth filter. Cutoff frequencies between 2 and 12 Hz were evaluated, and task-specific values were selected based on residual analysis and visual inspection of signal smoothness. A cutoff frequency of 4 Hz was selected for STA, STD, FWL, and SQU, and 2 Hz for STS; these values were applied consistently across joint degrees of freedom. Marker-based kinematic data were filtered using a fourth-order low-pass Butterworth filter with a 6 Hz cutoff frequency [16].
To enable comparison between systems, temporal alignment and static-pose angle offset correction were applied. Temporal alignment was performed by synchronizing trials using the peak of the right hip flexion-extension angle as a reference event. This event was selected because it provided a clearly identifiable feature in both measurement systems and allowed temporal alignment to be performed independently of the GRF signals, which represented one of the outcomes of the subsequent comparison. The same alignment criterion was applied consistently across repetitions. Task windows were manually selected from synchronized kinematic and force traces to isolate the active movement phase and exclude preparatory or residual motion; the selected windows are reported in the Supplementary Material. Angle offsets between OpenCap and PiG were computed from the static calibration pose acquired at the beginning of each trial and applied to the OpenCap joint-angle trajectories to reduce systematic differences due to model definitions, joint coordinate systems, and sign conventions. This correction was introduced to enable comparison of dynamic waveform behavior between the two modeling approaches rather than to assess absolute joint-angle agreement. Accordingly, the post-correction agreement metrics reported in the following analyses primarily characterize differences in waveform magnitude and shape after removal of the static model-dependent offset. The original static offsets are reported separately in Section 3.1 and Supplementary Figure S1 to retain information regarding absolute differences between the two systems in the reference pose.
All kinematic and GRF signals were time-normalized to 0–100% of task duration using linear interpolation to 101 samples.
The comparison focused on hip angles (flexion-extension, abduction-adduction, and internal-external rotation), knee flexion-extension, and ankle flexion-extension. Additionally, results on pelvis orientation (tilt, list, and rotation) are reported in Supplementary Material.

2.2.6. Ground Reaction Force Estimation

Experimental GRFs acquired from the force plates were decimated and filtered using a fourth-order bidirectional low-pass Butterworth filter with a cutoff frequency of 25 Hz [17].
Ground reaction forces were estimated in OpenCap/OpenSim using the example_kinetics.py processing workflow. The original workflow was adapted to enable stair negotiation and forward lunge analyses, which required task-specific configuration parameters to improve convergence and contact-event handling.
For stair ascent and descent, a dynamic floor-plane threshold of 40 cm was introduced to improve foot-contact detection during elevated movements. Task-specific temporal margins were also applied to reduce edge artifacts at the beginning and at the end of the simulations. The main optimization adjustments and simulation windows are reported in the Supplementary Material.
Estimated GRFs were further smoothed using a moving-average filter over ten samples. All GRFs were normalized to body weight (BW). For each trial, the computational time required for the GRF simulations was estimated using a PC equipped with a 16 GB graphics card; it ranged from 3 to 5 h.

2.2.7. Statistical Analysis

Kinematic and GRF signals were analyzed across the three repetitions of each task to assess within-participant inter-trial variability. Mean trajectories and standard deviations were computed for both experimental and simulated data.
Agreement between OpenCap and reference measurements was quantified using root mean square error (RMSE), Pearson correlation coefficient, and cosine similarity. These metrics were computed for joint kinematics and resultant GRFs across all tasks. Given the single-participant feasibility design, these agreement metrics are reported as descriptive point estimates for the analyzed trials and should not be interpreted as population-level validation or reliability statistics.

3. Results

3.1. Static Pose

Static-pose differences between the OpenCap and PiG models were observed mainly for pelvis tilt, ankle flexion-extension, and hip internal-external rotation. Offsets were below 5 degrees (deg) for hip flexion-extension and adduction-abduction, knee flexion-extension, pelvis list, and pelvis rotation. Larger offsets were observed for hip internal-external rotation (approximately 36 deg right and 29 deg left), ankle flexion-extension (approximately 10 deg right and 7 deg left), and pelvis tilt (approximately 12 deg). These offsets were used to align OpenCap angles to the PiG convention before waveform comparison. Detailed static-pose offsets are reported in Supplementary Figure S1. These static differences should be distinguished from the subsequent dynamic agreement metrics: the former characterize model-dependent differences in absolute joint-angle representation in the reference pose, whereas the latter characterize agreement in dynamic waveform behavior after removal of the static offset.

3.2. Kinematic Analysis

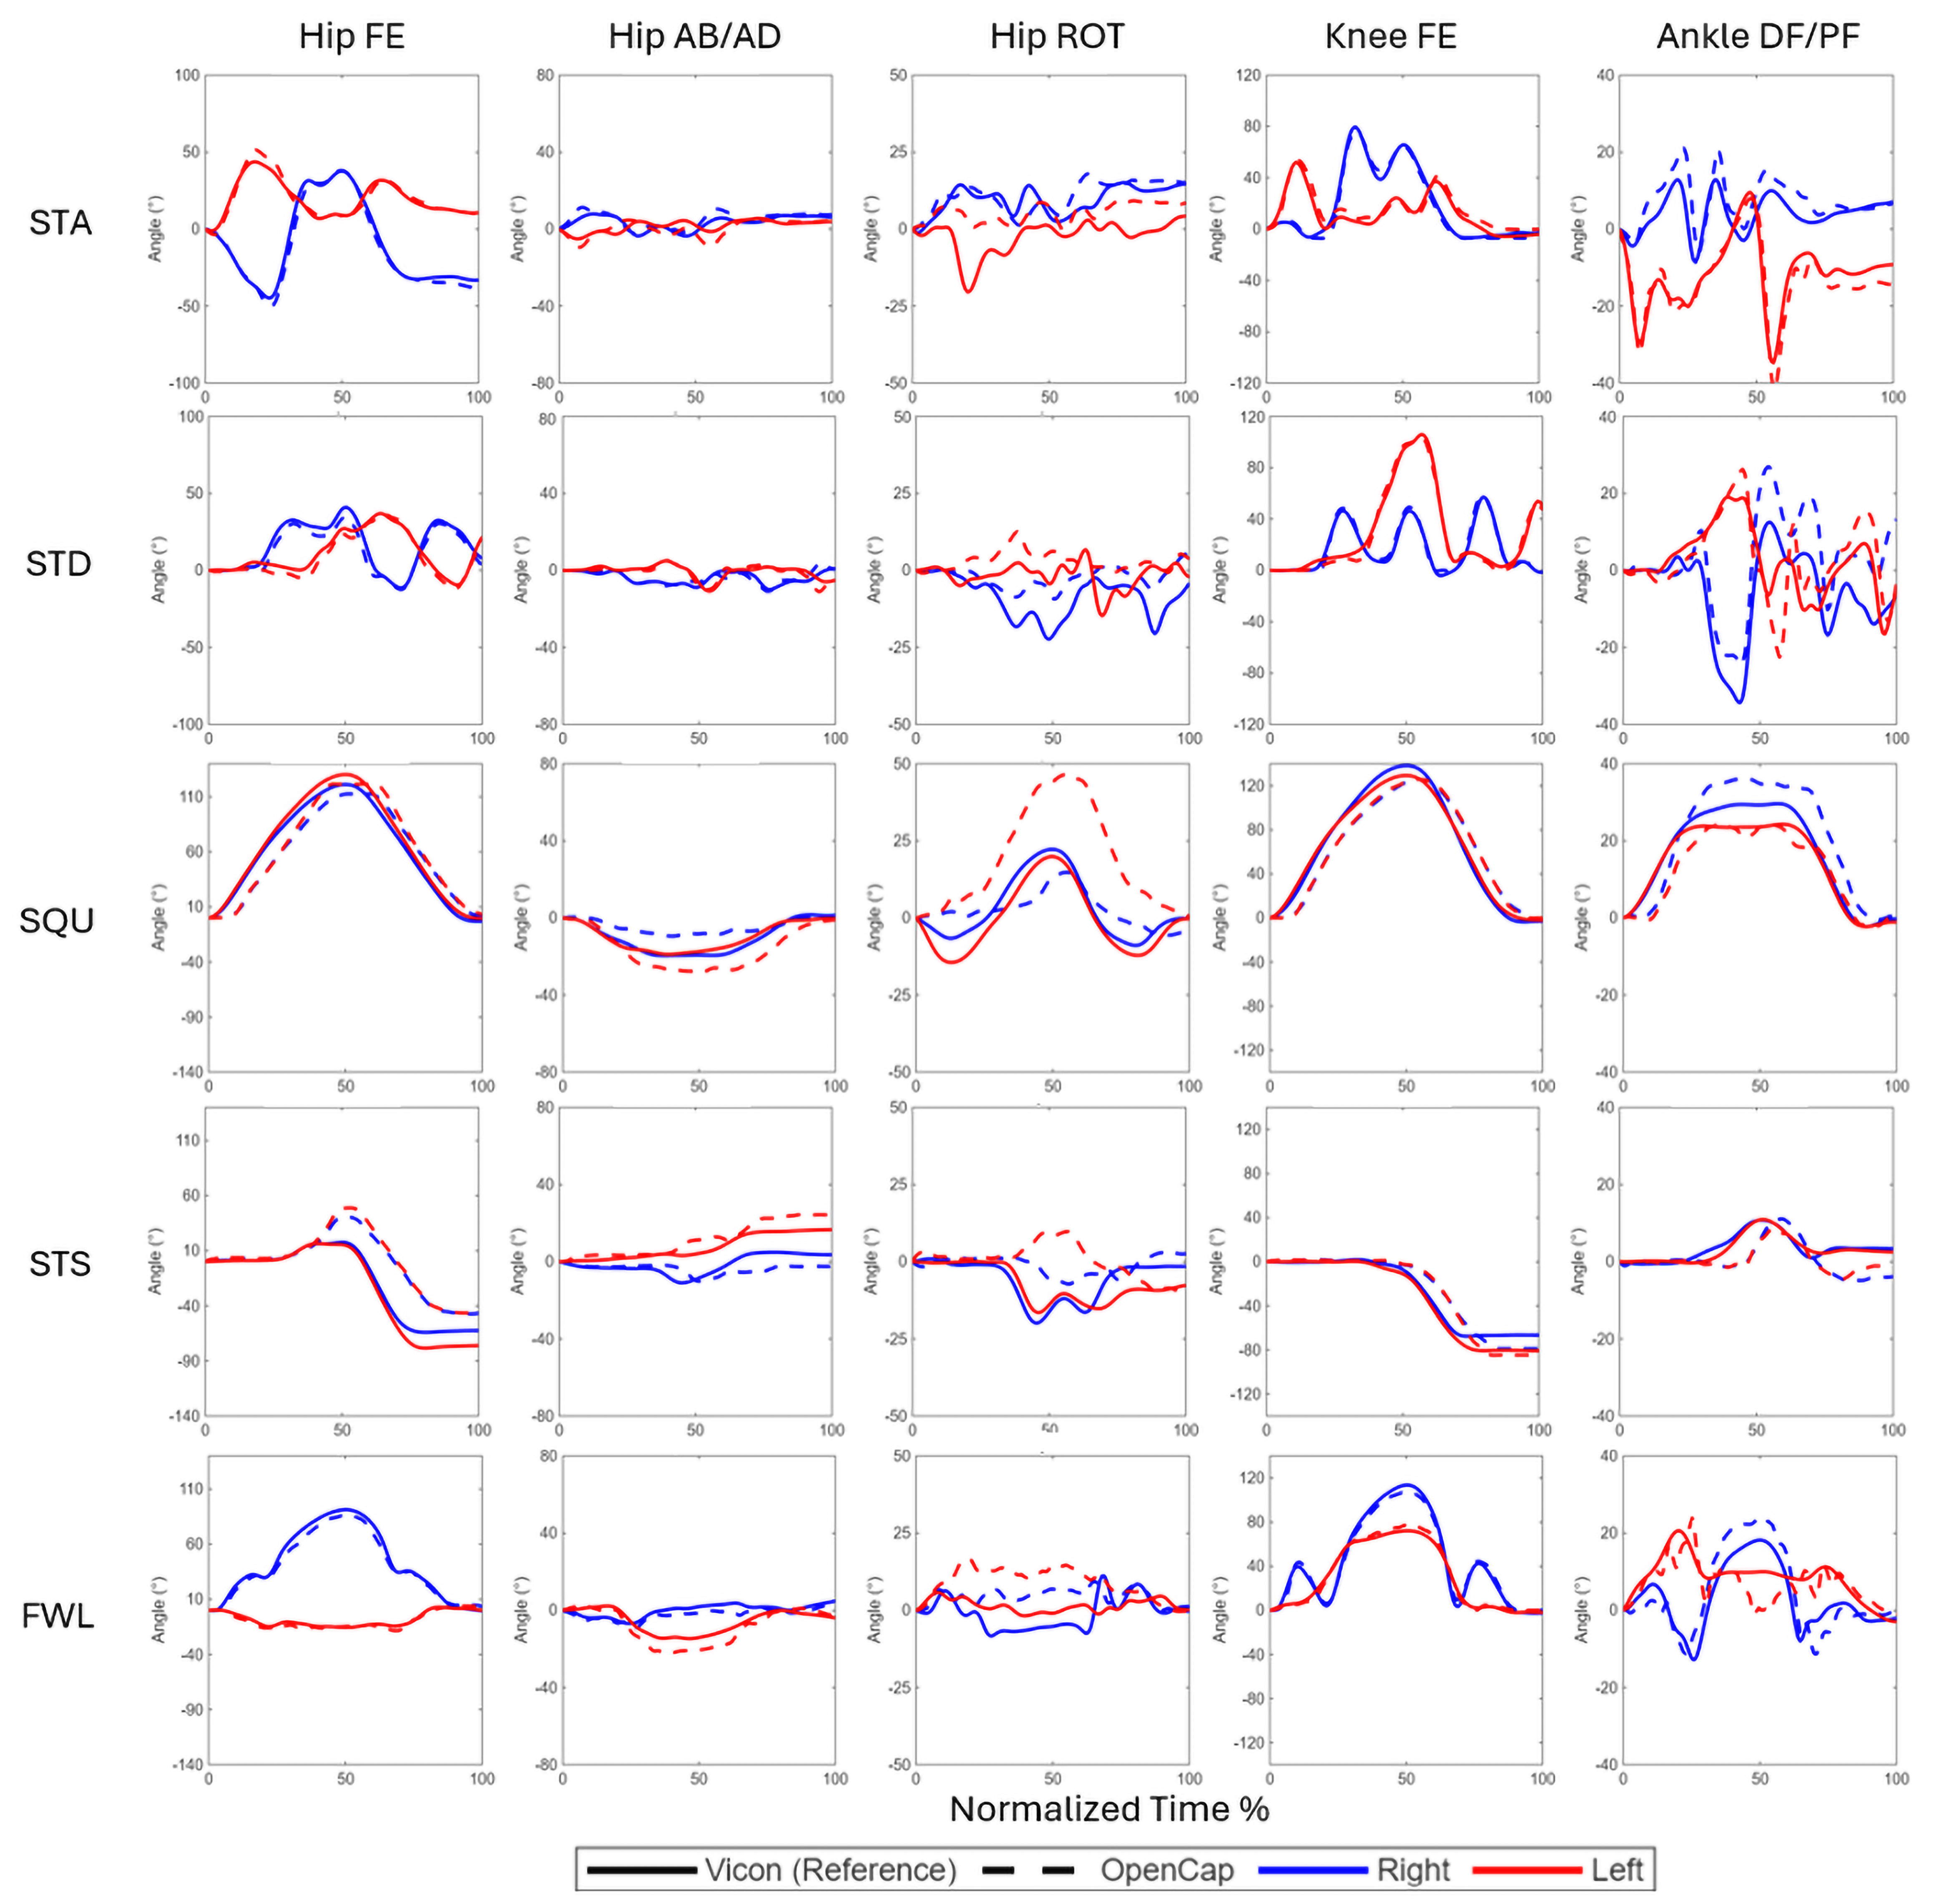
The aligned OpenCap and PiG models showed good agreement for sagittal-plane lower-limb kinematics across tasks (Figure 3). Knee flexion-extension exhibited RMSE values of 1.4–10.5 deg, Pearson correlations of 0.94–0.999, and cosine similarities above 0.97. Hip flexion-extension showed slightly larger errors but preserved the overall waveform shape across tasks.
Hip internal-external rotation showed the largest discrepancies, with RMSE exceeding 10 deg in several tasks and reaching 23.2 deg (right, SQU) and 17.3 deg (right, FWL). Ankle flexion-extension RMSE ranged from 1.4 deg (STS) to 9.3 deg (FWL). Pelvis rotations showed task-dependent variability; pelvis tilt during STS showed the weakest agreement (RMSE = 14.9 deg, Pearson = − 0.86, cosine similarity = 0.25), likely reflecting model-specific differences in pelvis kinematic definitions between OpenSim and PiG. Detailed kinematic metrics are reported in Supplementary Table S1.

3.3. Ground Reaction Forces

OpenCap simulations reproduced the overall trends of experimentally measured GRFs across tasks. Larger discrepancies were observed for low-amplitude horizontal force components, particularly during stair descent; therefore, quantitative analyses focused on resultant GRF magnitudes.
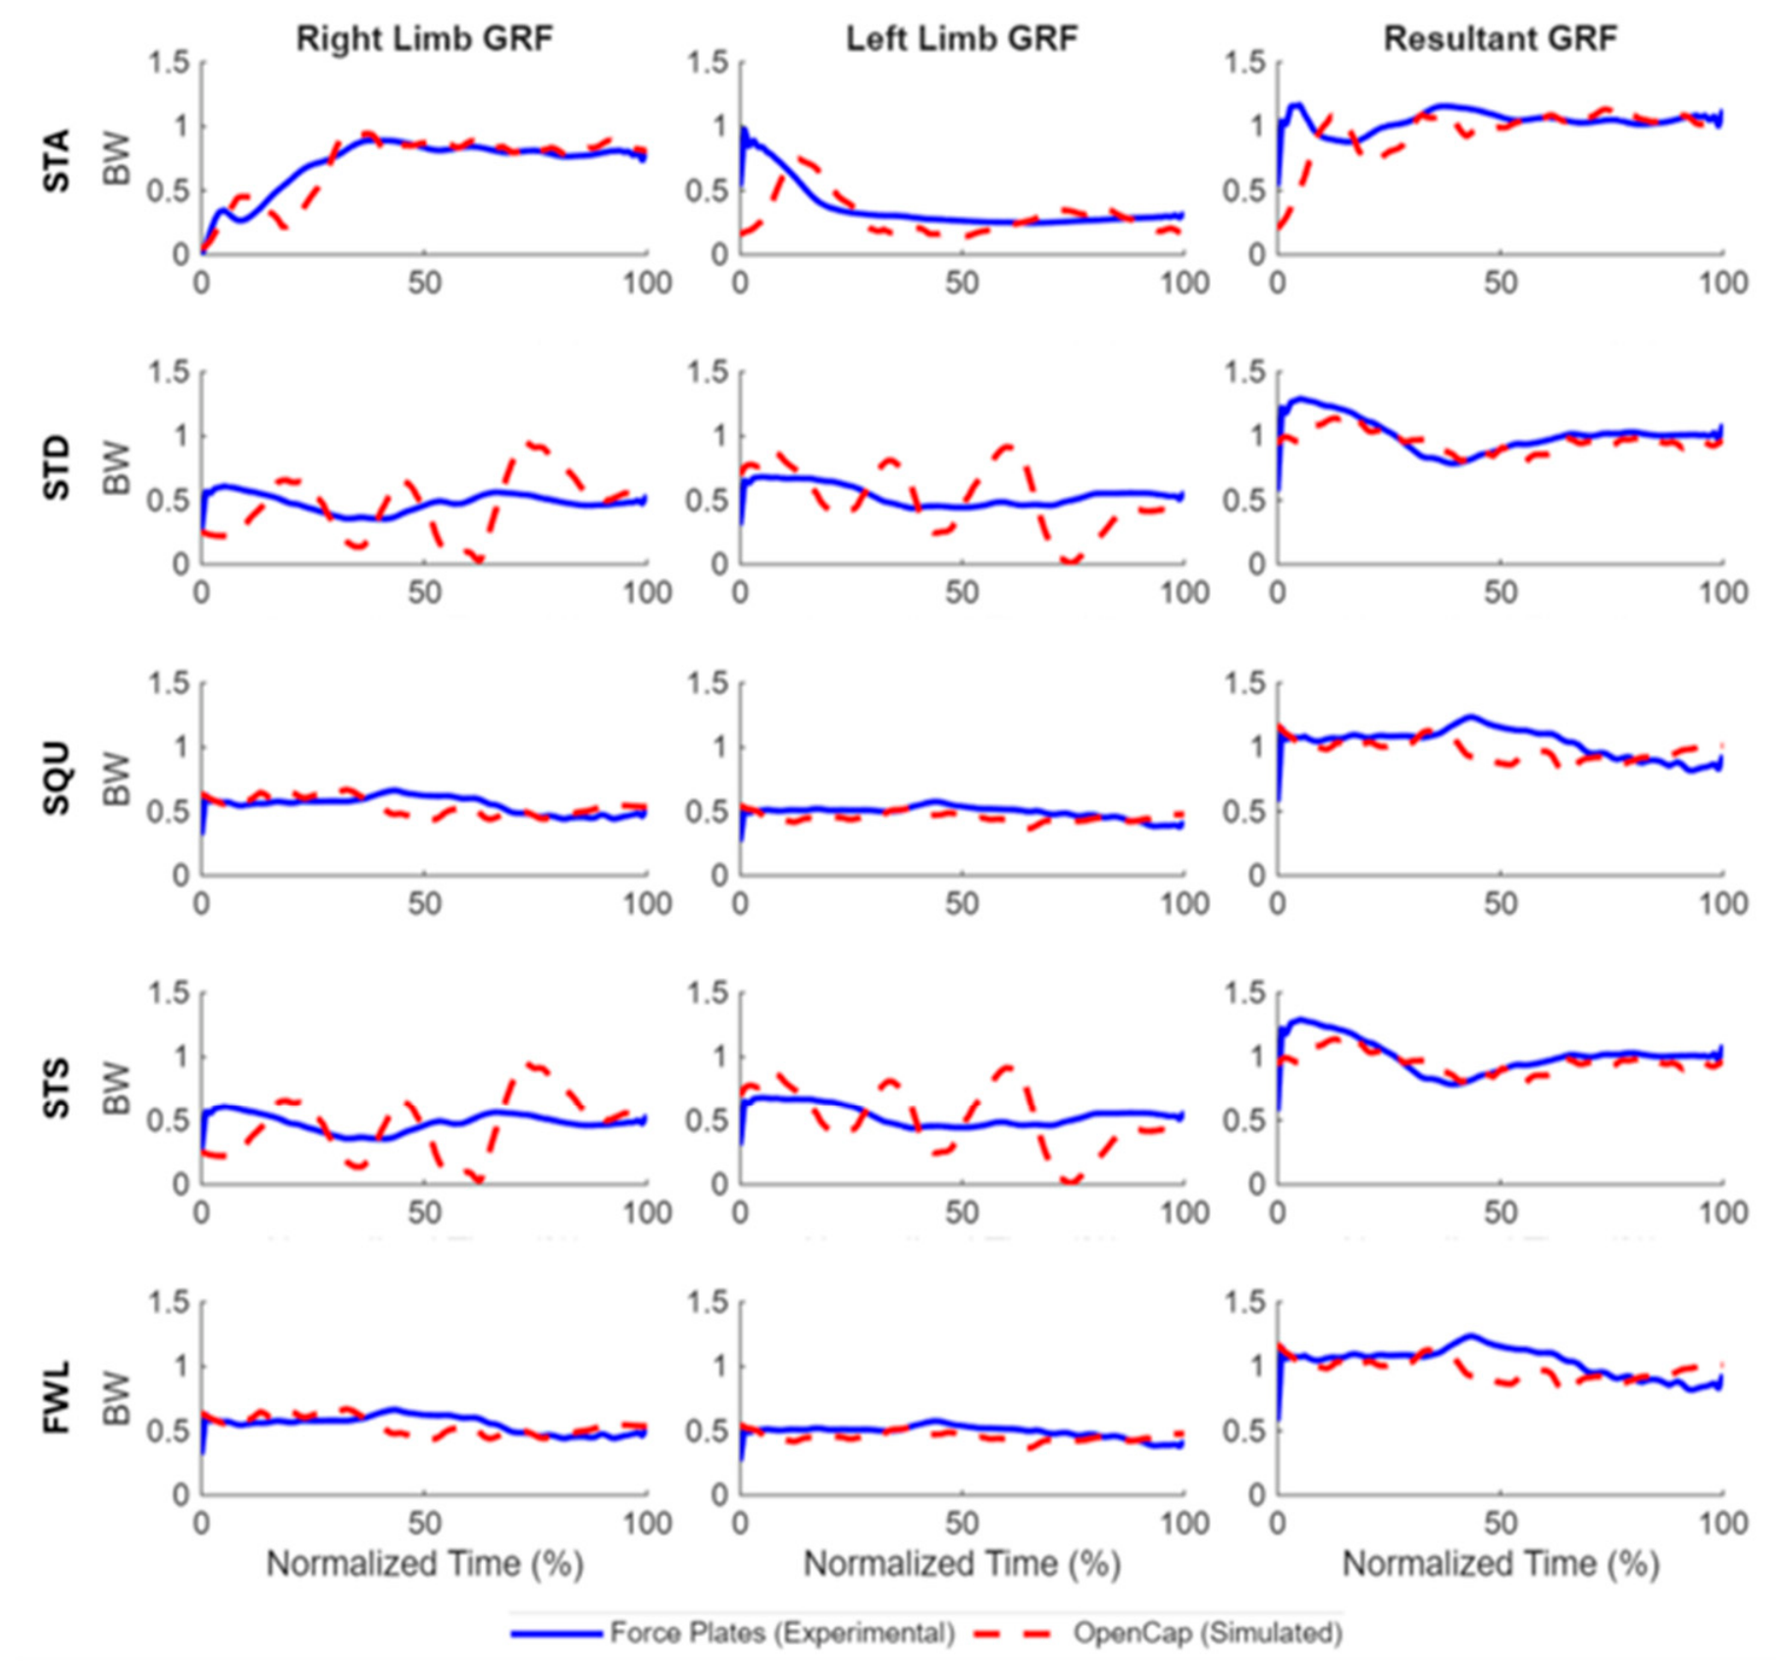
Figure 4 summarizes representative comparisons between experimental and simulated GRFs for all tasks. Simulated signals generally followed experimental profiles, although local fluctuations were observed during rapid loading transitions.

3.3.1. Within-Participant Inter-Trial Variability

Variability patterns observed in simulated GRFs were generally consistent with experimental measurements. Squat trials exhibited the lowest variability, whereas stair descent showed the highest variability across repetitions. Increased variability was primarily observed during rapid GRF loading and unloading phases. Detailed variability metrics are reported in Supplementary Table S2.

3.3.2. Qualitative Comparison Between Simulated and Experimental GRFs

A qualitative comparison between simulated and experimental GRFs showed that OpenCap reproduced the main temporal loading and unloading patterns across tasks (Figure 4). Local fluctuations and small timing differences remained visible during rapid transitions and foot-contact events, especially in stair negotiation. Moving-average smoothing reduced high-frequency oscillations and improved waveform readability without eliminating task-specific timing differences.
These fluctuations were most evident during stair descent, where earlier simulated contact events occasionally affected single-limb GRF estimation. Despite these local deviations, the resultant GRF was more stable than individual limb forces, suggesting partial compensation of timing and magnitude errors between limbs.
Quantitative comparisons between simulated and experimental resultant GRFs demonstrated overall good agreement across tasks (Supplementary Table S3). Cosine similarity values were high for all resultant GRFs (0.988–0.998), indicating strong agreement in waveform shape. RMSE values ranged from 0.069 BW for stair ascent to 0.167 BW for stair descent. Pearson correlations varied across tasks and limbs, particularly during squat and sit-to-stand, where relatively flat GRF profiles and low dynamic range amplified the influence of local fluctuations. In these cases, cosine similarity provided a more informative measure of waveform agreement than Pearson correlation alone.
These results justified using resultant GRFs as the primary kinetic outcome, while treating limb-specific load sharing as exploratory. Additionally, it should be noted that all reported results refer exclusively to the analyzed participant and trials and do not support population-level inference.

4. Discussion

The results revealed a variable-dependent performance pattern of smartphone-based estimations. Agreement was strongest for sagittal-plane lower-limb kinematics, particularly knee flexion-extension, which showed RMSE values of 1.4–10.5 deg, Pearson correlations of 0.94–0.999, and cosine similarities above 0.97. These findings indicate that the dominant temporal pattern of sagittal knee motion was preserved across the analyzed functional tasks and are consistent with previous OpenCap validation studies reporting higher accuracy for sagittal-plane motion than for frontal- and transverse-plane kinematics [5,7,8,9,10,11]. The knee flexion-extension RMSE values observed in the present study were also broadly consistent with those reported for related functional tasks [7,9]. Conversely, larger discrepancies were observed for hip internal-external rotation, pelvis motion during sit-to-stand, and ankle flexion-extension. Hip internal-external rotation was particularly sensitive, which may reflect the greater effect of small errors in reconstructed segment orientation on transverse-plane estimates, together with differences between the musculoskeletal representations used by OpenCap/OpenSim and PiG. Pelvis tilt during sit-to-stand represented the poorest agreement, with an RMSE of 14.9 deg, a negative Pearson correlation (r = −0.86), and low cosine similarity (0.25). Unlike a simple magnitude offset, this combination of metrics indicates substantial disagreement in the temporal evolution of the signal. The discrepancy may reflect differences in pelvis coordinate-system definitions and model constraints, together with the sensitivity of trunk-pelvis orientation estimates to markerless pose reconstruction during the large trunk displacement associated with sit-to-stand. Overall, these findings highlight that good agreement in selected sagittal-plane variables should not be generalized to all kinematic outputs of the markerless pipeline.
The GRF analysis demonstrated that OpenCap/OpenSim simulations reproduced the overall temporal behavior of experimental signals, particularly for resultant GRFs. Resultant GRF cosine similarity values ranged from 0.988 to 0.998, indicating strong agreement in waveform shape, whereas RMSE values ranged from 0.069 to 0.167 BW. This distinction is important because high waveform similarity does not necessarily imply equivalent force magnitude at each time point. Lower agreement for individual limbs further suggests that contact timing and inter-limb load sharing represent important sources of error, consistent with previous reports on markerless GRF estimation during gait and jumping tasks [12,13]. These limitations were most evident during stair descent, which produced the largest resultant GRF error and the greatest inter-trial variability. Stair descent combines elevated initial foot position, rapid loading following ground contact, and transitions between single- and double-support conditions, making estimated GRFs particularly sensitive to small errors in foot-contact timing. The greater stability of the resultant GRF compared with individual limb estimates suggests that part of the discrepancy was associated with the modeled distribution of load between limbs rather than with the overall external loading pattern. Consequently, resultant GRF waveform shape appears to be a more robust output of the present pipeline than limb-specific load sharing, although this observation remains limited to the single-participant feasibility dataset.
A key technical contribution of this study was the adaptation of the OpenCap kinetics workflow for elevated foot-contact conditions, including the dynamic floor-plane threshold and task-specific temporal margins required to achieve stable convergence during stair and lunge simulations. More broadly, the sensitivity observed during stair descent highlights the limitations of generalized processing settings for functional tasks involving elevated or rapidly changing contacts. Moving-average filtering reduced high-frequency oscillations in the simulated GRFs, but the need for task-specific parameter adjustment indicates that noise propagation from video-based pose estimation and contact-model assumptions remains an important limitation of the current workflow. Further improvements in pose estimation, contact modeling, and processing automation will therefore be necessary to improve robustness across heterogeneous functional movement categories.
This issue is particularly relevant when OpenCap is considered within the broader landscape of open-source markerless motion-analysis tools based on consumer-grade cameras, including MediaPipe [18], FreeMoCap [19], and Pose2Sim [20]. These tools address different stages of the biomechanical processing pipeline. MediaPipe Pose provides efficient, real-time monocular detection of body keypoints, but requires additional processing and biomechanical assumptions to derive anatomically meaningful joint kinematics. FreeMoCap and Pose2Sim extend pose estimation to multi-view 3D reconstruction and provide greater flexibility in camera selection and processing configurations, with Pose2Sim also supporting OpenSim-based kinematic analysis. However, their customization generally requires greater technical expertise, and additional modeling is needed to estimate movement dynamics. By contrast, OpenCap integrates synchronized smartphone acquisition, AI-based keypoint detection and virtual-marker augmentation, musculoskeletal modeling, and physics-based GRF estimation within a more standardized workflow. AI therefore primarily contributes to converting video data into motion descriptors that can be used by biomechanical models, reducing the need for physical markers and manual tracking.
From a practical perspective, the integrated OpenCap workflow may offer potential for exploratory monitoring of overall movement patterns and resultant loading profiles using consumer-grade devices. However, the present single-participant findings should not be interpreted as evidence supporting individual-level clinical assessment. In particular, the larger discrepancies observed for transverse-plane hip kinematics, pelvis motion during sit-to-stand, and limb-specific GRFs indicate that variables requiring high spatial or load-sharing accuracy should currently be interpreted with caution. Moreover, the need for task-specific parameter tuning and the substantial computational time required for GRF estimation limit the immediate applicability of the adapted pipeline as a rapid point-of-care assessment tool. At its current stage, the workflow may therefore be more appropriate for methodological and exploratory research, while its use for clinical decision-making requires validation in larger and more diverse populations and assessment of between-session reliability.
This study has several limitations. First, the analysis was performed on a single healthy participant, with three repetitions per task. Therefore, the findings should be interpreted as evidence of technical feasibility and variable-specific behavior of the investigated pipeline rather than as population-level validation. The present design does not allow conclusions regarding inter-subject variability, between-session reliability, or performance in pathological populations, which should be addressed in subsequent larger-scale studies. Second, task-specific tuning of the OpenCap kinetics workflow was necessary for stair and lunge movements, reducing the level of automation. Finally, the simplified foot-ground contact model and the dependence on video-based pose estimation may have contributed to inaccuracies in multiplanar kinematics and GRF estimation.
Future work should include larger cohorts, clinical and sport-specific populations, repeated-session reliability analyses, and additional tasks involving elevated or asymmetric contacts. Improvements in marker augmentation, contact modeling, and task-specific musculoskeletal optimization may further enhance the accuracy and robustness of markerless kinematic and kinetic evaluation. However, the current OpenCap/OpenSim workflow for GRF estimation can be computationally demanding and requires a stable internet connection. More recently, OpenGRF [21] has been introduced as a web-independent OpenSim-based framework for estimating GRFs directly from kinematic data. Future studies could therefore compare OpenGRF with the current OpenCap/OpenSim approach to investigate whether alternative GRF estimation strategies may offer complementary advantages, particularly for tasks involving challenging foot-ground interactions. Such a comparison was beyond the scope of the present study and represents a potential direction for future research.

5. Conclusions

This feasibility study demonstrated the technical feasibility of adapting the OpenCap/OpenSim pipeline to estimate lower-limb kinematics and GRFs during functional tasks, including stair negotiation and forward lunge. Performance was strongly dependent on the biomechanical variable and task considered. Agreement with laboratory reference measurements was highest for sagittal-plane lower-limb kinematics, particularly knee flexion-extension, and for resultant GRF waveform shape, whereas larger discrepancies were observed for selected multiplanar kinematics and limb-specific force estimates. Stair descent represented the most challenging condition, highlighting the sensitivity of markerless kinetic estimation to elevated foot contacts, rapid loading transitions, and contact-timing assumptions. The task-specific adaptations required for stair and lunge simulations further indicate that the current kinetics workflow is not yet fully generalizable across functional movement conditions. Overall, these findings support the use of the investigated pipeline as a methodological framework for further research on smartphone-based biomechanical analysis rather than as a validated tool for individual-level clinical assessment. Larger multi-participant and repeated-session studies are required to establish its generalizability, reliability, and potential clinical utility.

Supplementary Materials

The following supporting information can be downloaded at: https://www.mdpi.com/article/10.3390/app16189211/s1.

Author Contributions

Conceptualization, R.S., F.D.P., L.M.; methodology, R.S. and A.C.; software, R.S. and A.C.; validation, R.S. and A.C.; formal analysis, F.D.P., L.M.; investigation, R.S., A.C.; resources: R.S.; data curation, R.S., A.C.; writing—original draft preparation, R.S. and L.M.; writing—review and editing, R.S., A.C., L.M., F.D.P.; visualization, R.S.; supervision, F.D.P. and L.M.; project administration, L.M.; funding acquisition, L.M. All authors have read and agreed to the published version of the manuscript.

Funding

This work was supported by the European Union—NextGenerationEU—National Recovery and Resilience Plan (NRRP), Mission 4 Component 2, Investment No. 1.1, PRIN 2022, D.D. 104, 02/02/2022, project “In Silico Trials for Hip Replacements to evaluate the safety of new joint replacement designs”, CUP I53D23001820006.

Institutional Review Board Statement

The study was conducted in accordance with the Declaration of Helsinki, and the protocol was approved by the BioEthics Committee of the University of Pisa (“Analisi del movimento in ambito sportivo e riabilitativo” Prot.23/2024) on 22 March 2024.

Informed Consent Statement

Informed consent was obtained from the subject involved in the study.

Data Availability Statement

The original contributions presented in this study are included in the article/Supplementary Material. Further inquiries can be directed to the corresponding author.

Acknowledgments

The authors acknowledge Andrea Di Pietro for his contribution during the experimental sessions.

Conflicts of Interest

The authors declare no conflicts of interest.

References

  1. Roetenberg, D.; Luinge, H.J.; Sylcke, P. Xsens MVN: Full 6DOF Human Motion Tracking using Miniature Inertial Sensors, ResearchGate. Available online: https://www.researchgate.net/publication/239920367_Xsens_MVN_Full_6DOF_human_motion_tracking_using_miniature_inertial_sensors (accessed on 29 July 2025).
  2. Cao, Z.; Simon, T.; Wei, S.-E.; Sheikh, Y. OpenPose: Realtime Multi-Person 2D Pose Estimation Using Part Affinity Fields. IEEE Trans. Pattern Anal. Mach. Intell. 2021, 43, 172–186. [Google Scholar] [CrossRef] [Scilit] [PubMed]
  3. Shotton, J.; Fitzgibbon, A.; Cook, M.; Sharp, T.; Finocchio, M.; Moore, R.; Kipman, A.; Blake, A. Real-time human pose recognition in parts from single depth images. In Proceedings of the CVPR 2011, Colorado Springs, CO, USA, 20–25 June 2011; pp. 1297–1304. [Google Scholar] [CrossRef] [Scilit]
  4. Walker, J.; Thomas, A.; Lunn, D.E.; Nicholson, G.; Tucker, C.B. Concurrent validity of Theia3D markerless motion capture for detecting sagittal kinematic differences between gait speeds. J. Sports Sci. 2025, 43, 1560–1571. [Google Scholar] [CrossRef] [Scilit] [PubMed]
  5. Boswell, M.A.; Kidziński, Ł.; Hicks, J.L.; Uhlrich, S.D.; Falisse, A.; Delp, S.L. Smartphone videos of the sit-to-stand test predict osteoarthritis and health outcomes in a nationwide study. npj Digit. Med. 2023, 6, 32. [Google Scholar] [CrossRef] [Scilit] [PubMed]
  6. Uhlrich, S.D.; Falisse, A.; Kidziński, Ł.; Muccini, J.; Ko, M.; Chaudhari, A.S.; Hicks, J.L.; Delp, S.L. OpenCap: Human movement dynamics from smartphone videos. PLoS Comput. Biol. 2023, 19, e1011462. [Google Scholar] [CrossRef] [Scilit] [PubMed]
  7. Turner, J.A.; Chaaban, C.R.; Padua, D.A. Validation of OpenCap: A low-cost markerless motion capture system for lower-extremity kinematics during return-to-sport tasks. J. Biomech. 2024, 171, 112200. [Google Scholar] [CrossRef] [Scilit] [PubMed]
  8. Lima, Y.L.; Collings, T.; Hall, M.; Bourne, M.N.; Diamond, L.E. Validity and reliability of trunk and lower-limb kinematics during squatting, hopping, jumping and side-stepping using OpenCap markerless motion capture application. J. Sports Sci. 2024, 42, 1847–1858. [Google Scholar] [CrossRef] [Scilit] [PubMed]
  9. Svetek, A.; Morgan, K.; Burland, J.; Glaviano, N.R. Validation of OpenCap on lower extremity kinematics during functional tasks. J. Biomech. 2025, 183, 112602. [Google Scholar] [CrossRef] [Scilit] [PubMed]
  10. Horsak, B.; Eichmann, A.; Lauer, K.; Prock, K.; Krondorfer, P.; Siragy, T.; Dumphart, B. Concurrent validity of smartphone-based markerless motion capturing to quantify lower-limb joint kinematics in healthy and pathological gait. J. Biomech. 2023, 159, 111801. [Google Scholar] [CrossRef] [Scilit] [PubMed]
  11. Horsak, B.; Kainz, H.; Dumphart, B. Repeatability and minimal detectable change including clothing effects for smartphone-based 3D markerless motion capture. J. Biomech. 2024, 175, 112281. [Google Scholar] [CrossRef] [Scilit] [PubMed]
  12. Verheul, J.; Robinson, M.A.; Burton, S. Jumping towards field-based ground reaction force estimation and assessment with OpenCap. J. Biomech. 2024, 166, 112044. [Google Scholar] [CrossRef] [Scilit] [PubMed]
  13. Jamali, P.; Chou, L.-S.; Catena, R.D. Whole-cycle and time-specific validation of a GUI-based ground reaction force estimation tool for clinical gait analysis without a force plate. Med. Eng. Phys. 2025, 141, 104366. [Google Scholar] [CrossRef] [Scilit] [PubMed]
  14. Rajagopal, A.; Dembia, C.L.; DeMers, M.S.; Delp, D.D.; Hicks, J.L.; Delp, S.L. Full-Body Musculoskeletal Model for Muscle-Driven Simulation of Human Gait. IEEE Trans. Biomed. Eng. 2016, 63, 2068–2079. [Google Scholar] [CrossRef] [Scilit] [PubMed]
  15. Lai, A.K.M.; Arnold, A.S.; Wakeling, J.M. Why are Antagonist Muscles Co-activated in My Simulation? A Musculoskeletal Model for Analysing Human Locomotor Tasks. Ann. Biomed. Eng. 2017, 45, 2762–2774. [Google Scholar] [CrossRef] [Scilit] [PubMed]
  16. Crenna, F.; Rossi, G.B.; Berardengo, M. Filtering Biomechanical Signals in Movement Analysis. Sensors 2021, 21, 4580. [Google Scholar] [CrossRef] [Scilit] [PubMed]
  17. Liu, D.; He, M.; Hou, M.; Ma, Y. Deep learning based ground reaction force estimation for stair walking using kinematic data. Measurement 2022, 198, 111344. [Google Scholar] [CrossRef] [Scilit]
  18. Bazarevsky, V.; Grishchenko, I.; Raveendran, K.; Zhu, T.; Zhang, F.; Grundmann, M. BlazePose: On-device real-time body pose tracking. arXiv 2020, arXiv:2006.10204. [Google Scholar] [CrossRef] [Scilit]
  19. Matthis, J.S.; Cherian, A. FreeMoCap: A Free, Open-Source Markerless Motion Capture System, Version 0.0.54; Zenodo: Geneva, Switzerland, 2022. [Google Scholar] [CrossRef]
  20. Pagnon, D.; Domalain, M.; Reveret, L. Pose2Sim: An end-to-end workflow for 3D markerless sports kinematics—Part 1: Robustness. Sensors 2021, 21, 6530. [Google Scholar] [CrossRef] [Scilit] [PubMed]
  21. Di Pietro, A.; Di Puccio, F.; Modenese, L. OpenGRF: Prediction of ground reaction forces and moments during activities of daily living using OpenSim. J. R. Soc. Interface 2026, 23, 20260264. [Google Scholar] [CrossRef]
Figure 1. Schematic representation of the experimental setup combining marker-based and markerless motion analysis systems and Vicon’s global reference system.
Applsci 16 09211 g001
Figure 2. (A) OpenCap virtual marker set (shown in pink) and joint reference; (B) PiG marker set (shown in blue) and joint reference frame.
Applsci 16 09211 g002
Figure 3. Comparison of lower-limb joint kinematics obtained from Vicon and OpenCap across the five functional tasks: stair ascent (STA), stair descent (STD), squat (SQU), sit-to-stand (STS), and forward lunge (FWL). Solid lines represent Vicon measurements, whereas dashed lines represent OpenCap estimates. Hip flexion-extension (FE), hip abduction-adduction (AB/AD), hip internal-external rotation (Rot), knee flexion-extension (FE), and ankle dorsiflexion-plantarflexion (DF/PF) are shown for the right and left limbs. Curves are plotted over normalized task duration (0–100%).
Applsci 16 09211 g003
Figure 4. Comparison of experimental and OpenCap-estimated ground reaction forces (GRFs) across the five functional tasks: stair ascent (STA), stair descent (STD), squat (SQU), sit-to-stand (STS), and forward lunge (FWL). Experimental GRFs measured with force plates are shown as solid blue lines, whereas OpenCap-estimated GRFs are shown as dashed red lines. Results are reported for the right limb (left column), left limb (middle column), and resultant GRF (right column). GRFs are normalized to BW and plotted over normalized task duration (0–100%).
Applsci 16 09211 g004
Disclaimer/Publisher’s Note: The statements, opinions and data contained in all publications are solely those of the individual author(s) and contributor(s) and not of MDPI and/or the editor(s). MDPI and/or the editor(s) disclaim responsibility for any injury to people or property resulting from any ideas, methods, instructions or products referred to in the content.