Article

A Novel Type of Pneumatic Rotary Positioner Using Three-Phase Pressure Commutation

Department of Mechatronics, Faculty of Mechanical Engineering, Politehnica University Timisoara, 1 Bvd. Mihai Viteazul, 300222 Timisoara, Romania
*
Author to whom correspondence should be addressed.
Actuators 2026, 15(4), 192; https://doi.org/10.3390/act15040192
Submission received: 31 January 2026 / Revised: 26 March 2026 / Accepted: 29 March 2026 / Published: 31 March 2026
(This article belongs to the Special Issue Actuation and Sensing of Intelligent Soft Robots—2nd Edition)

Abstract

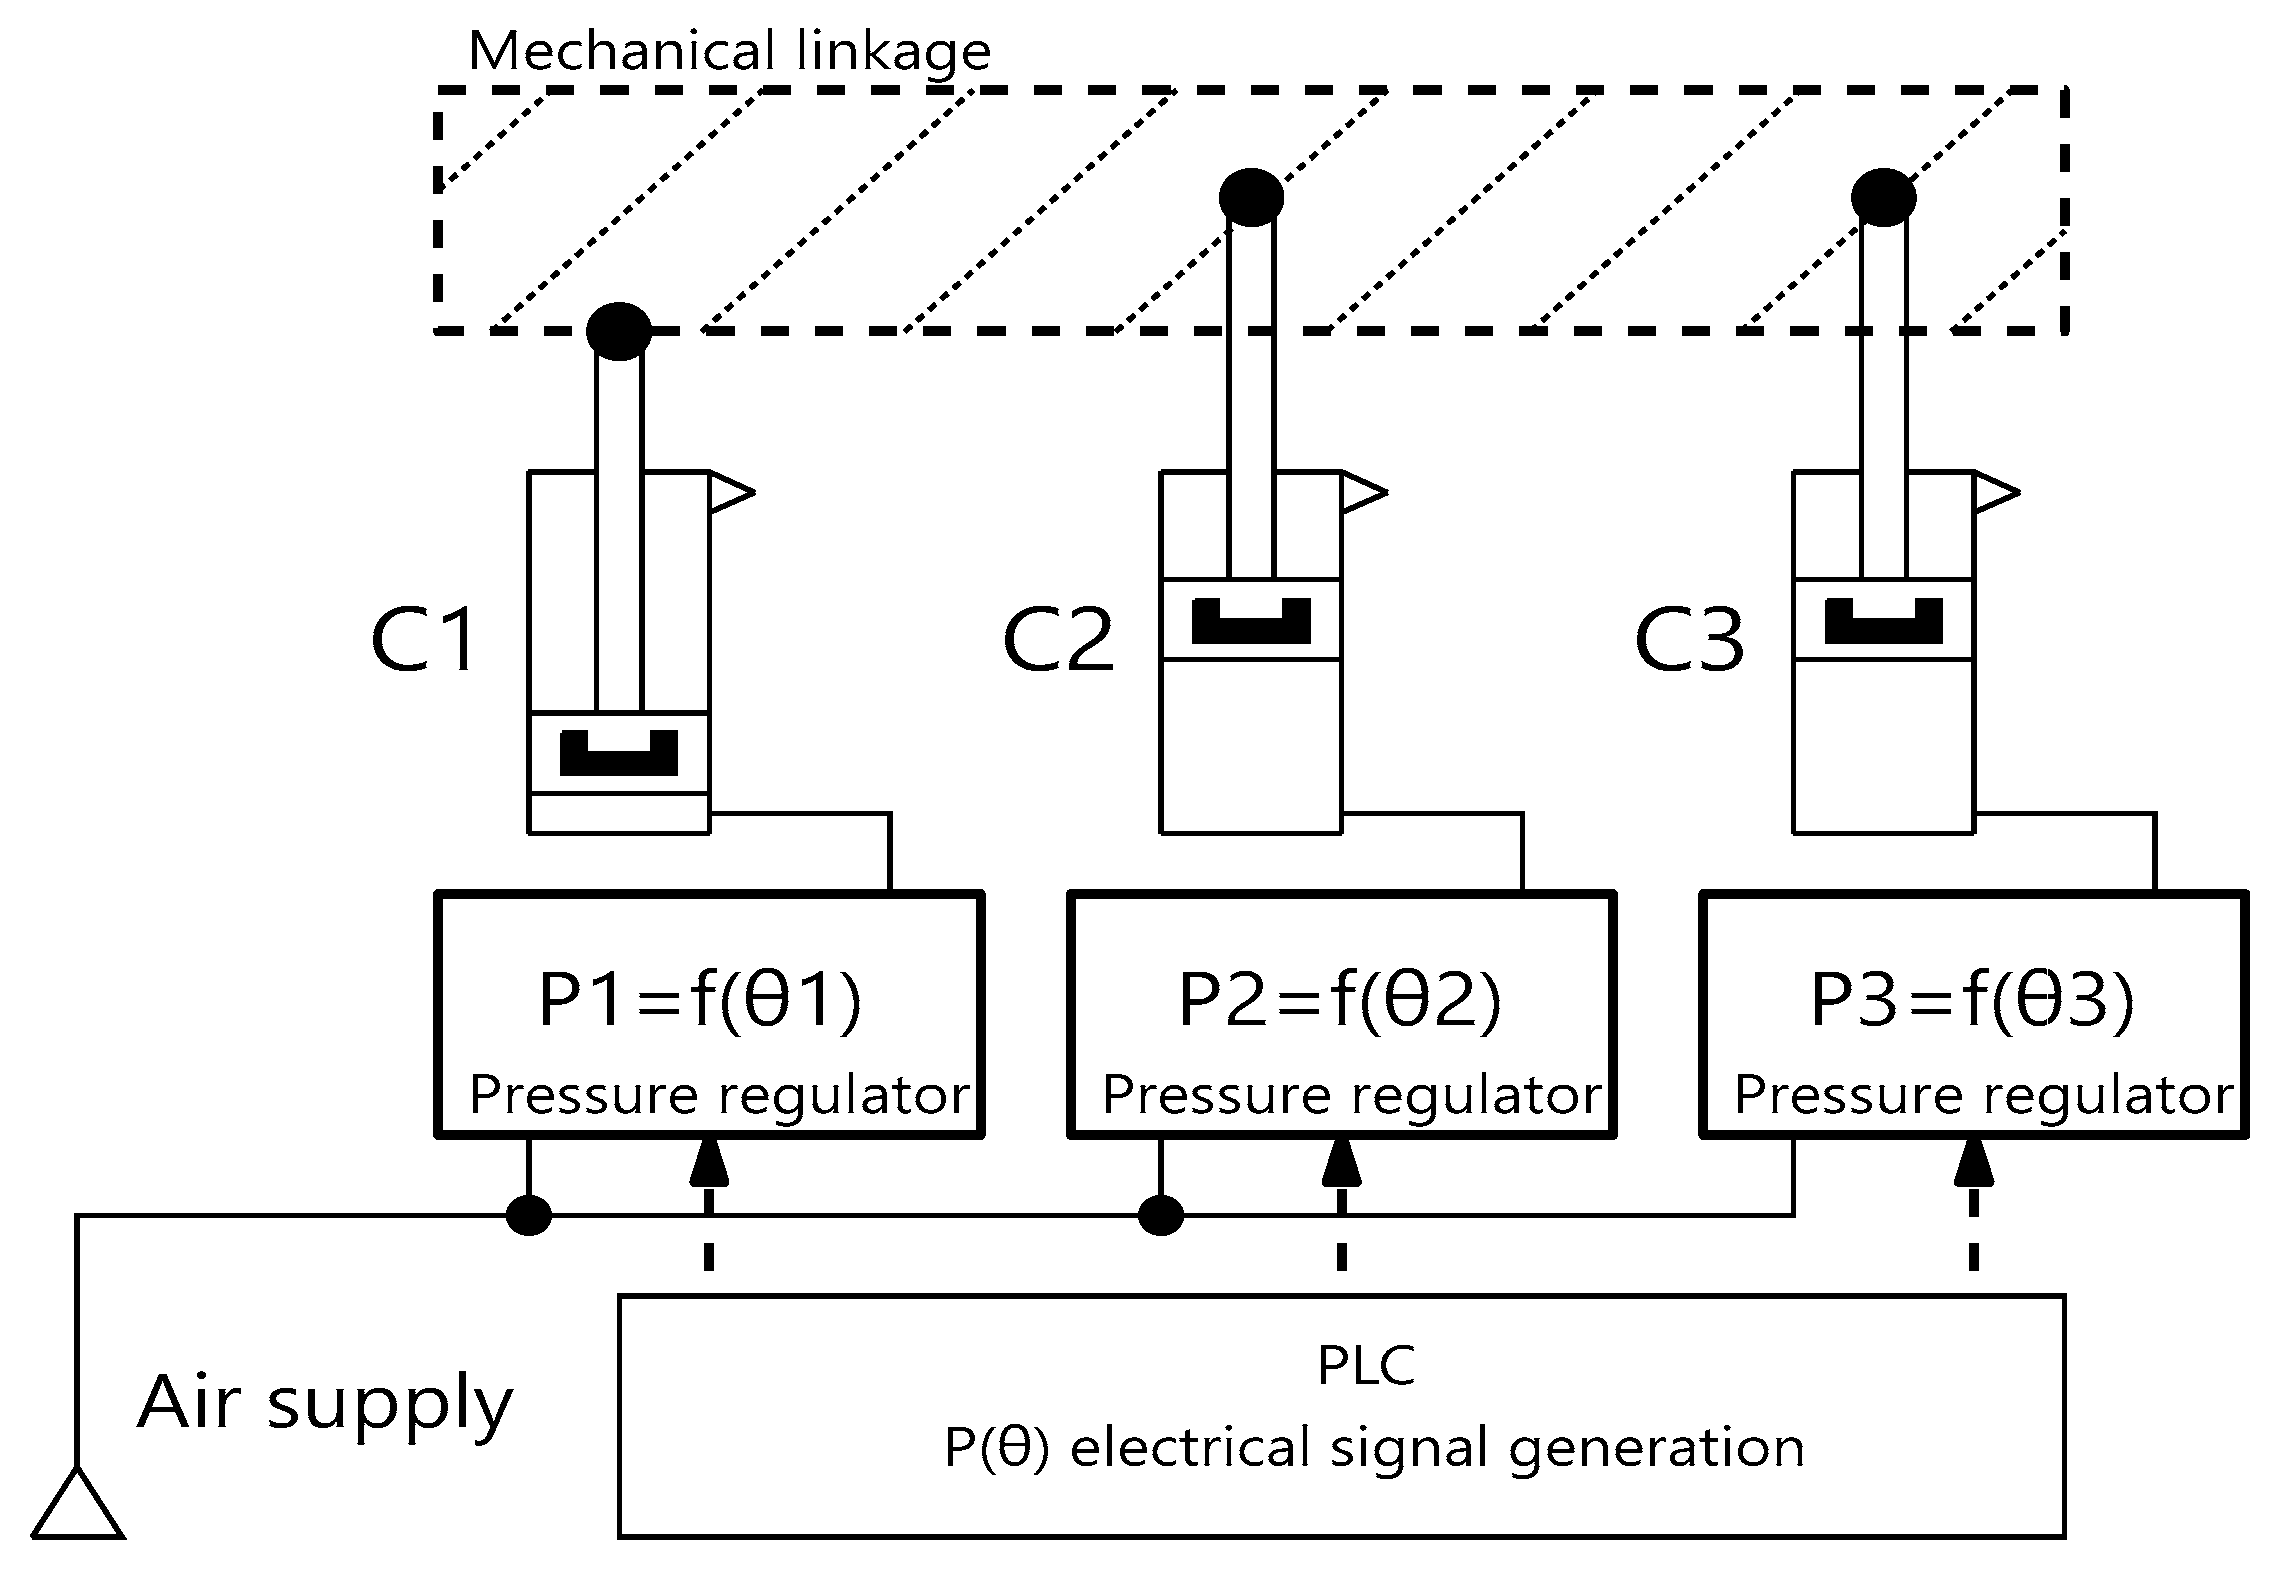
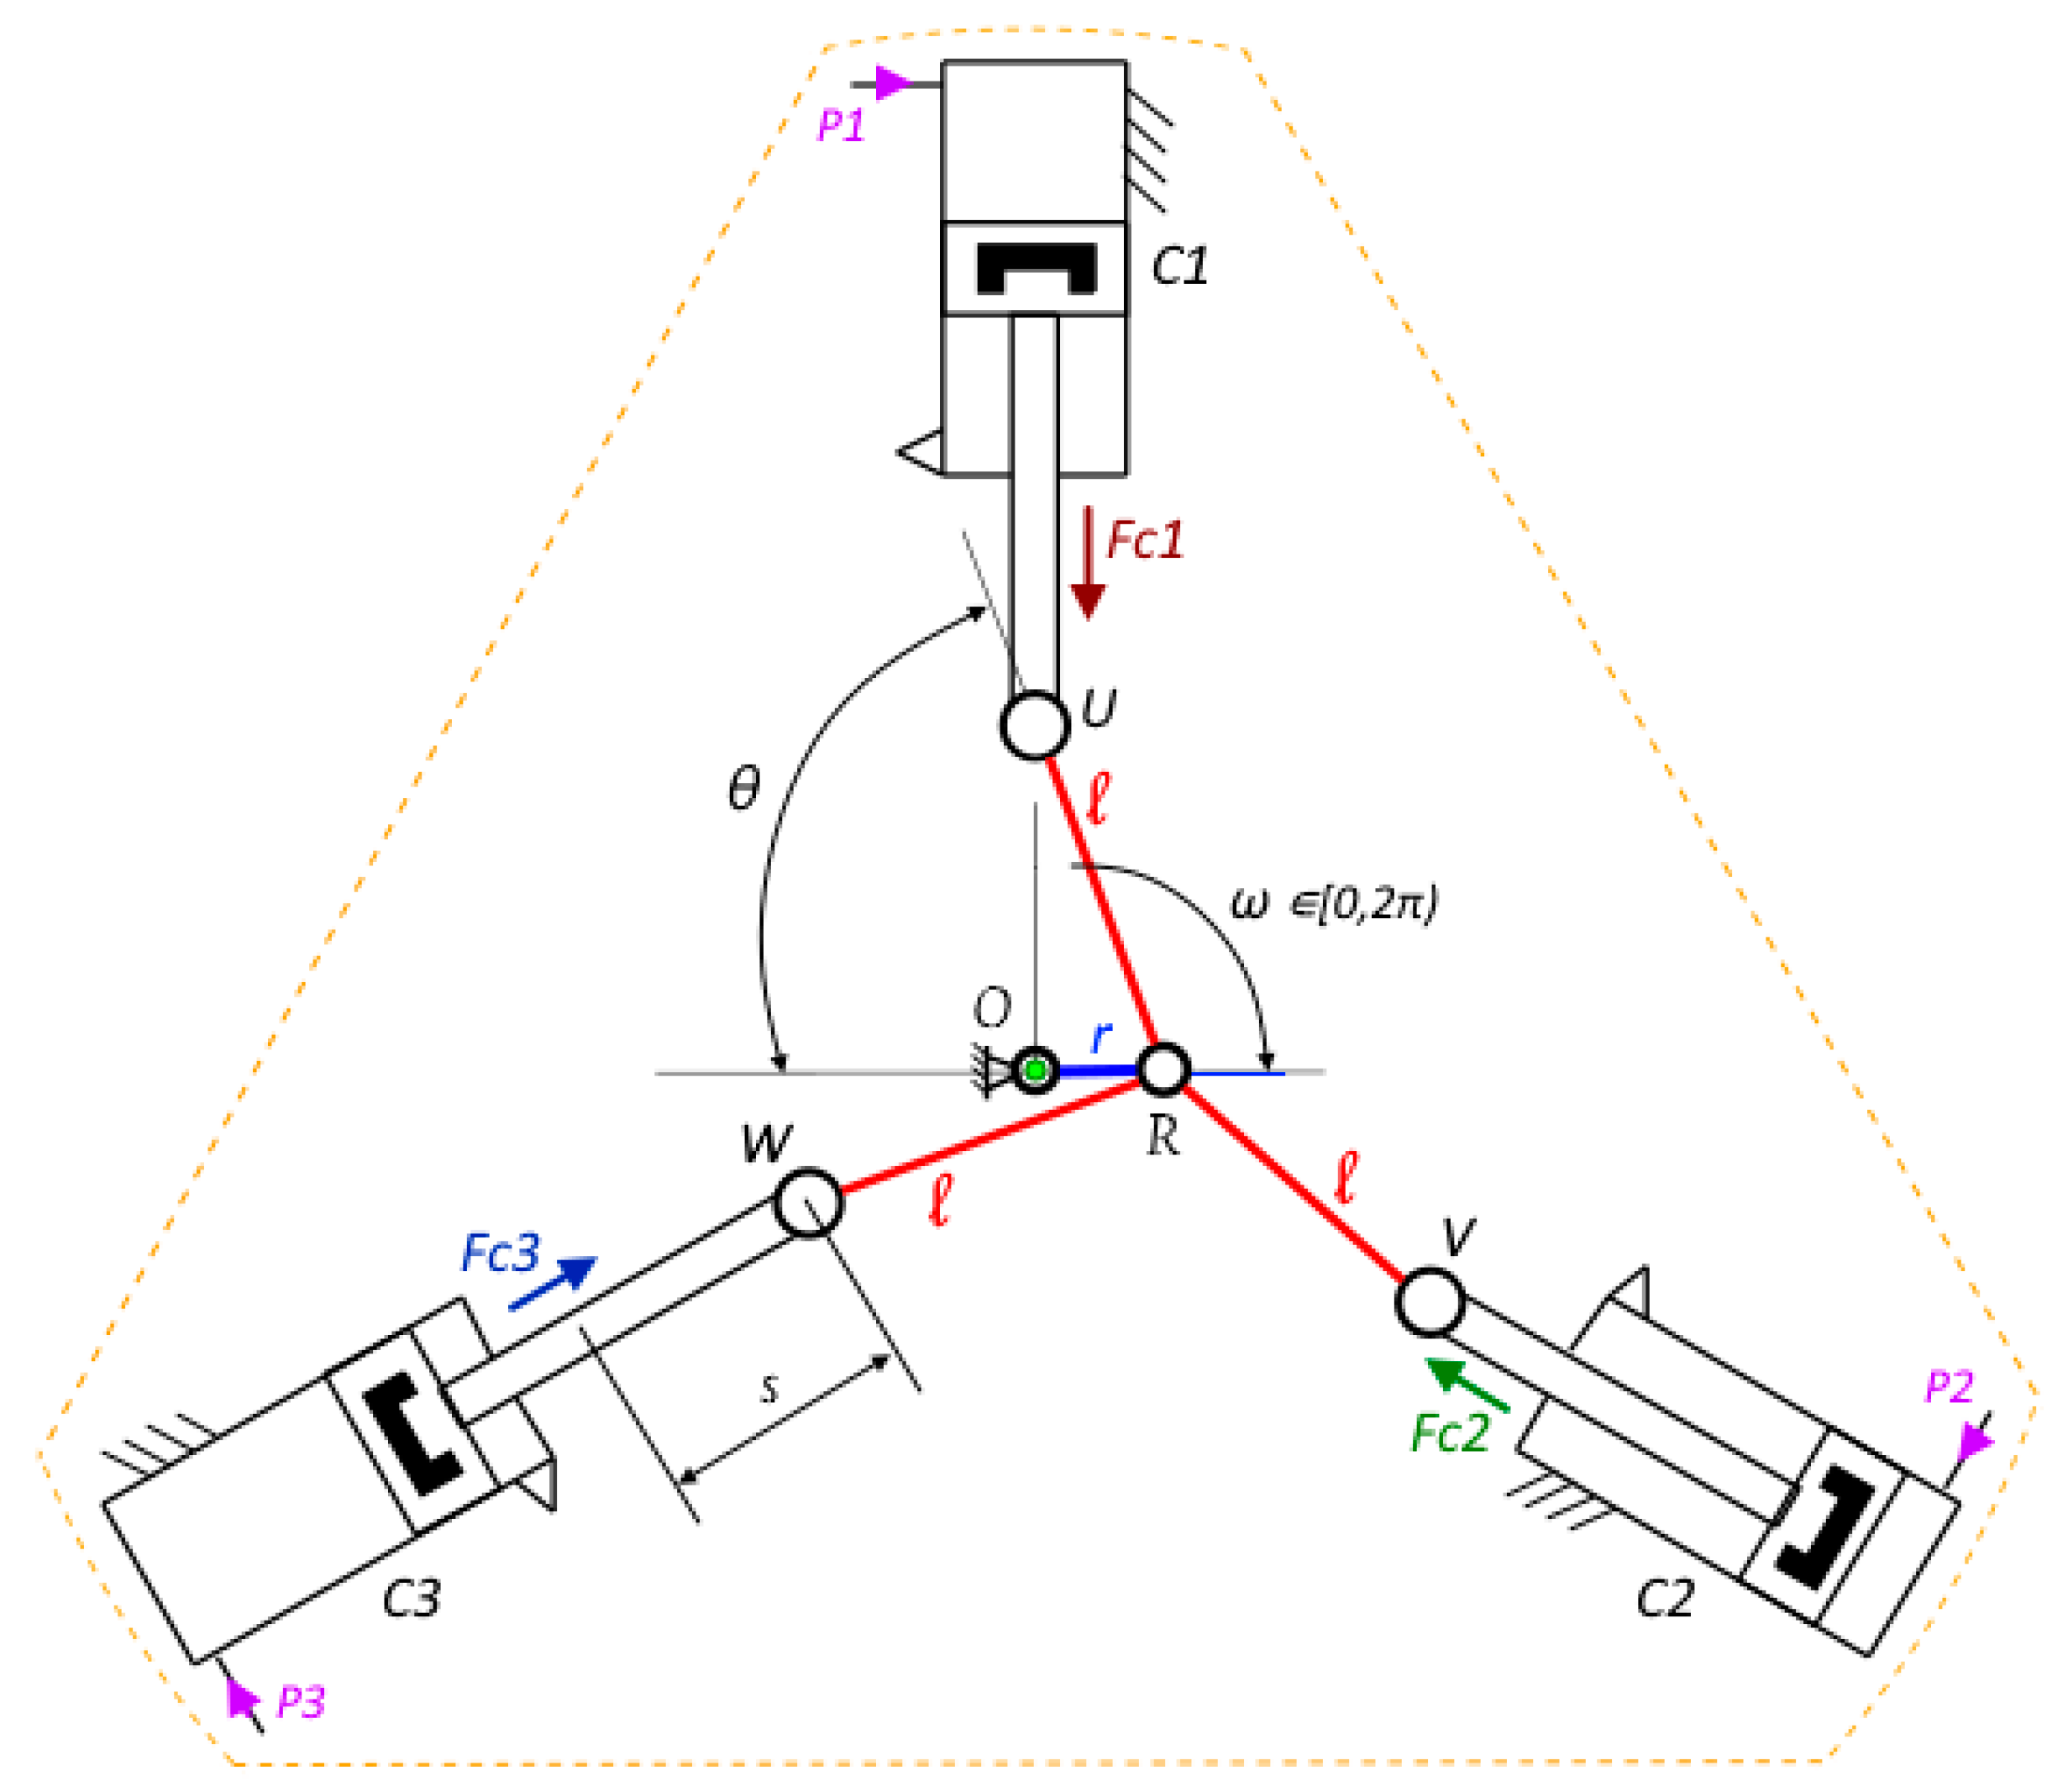
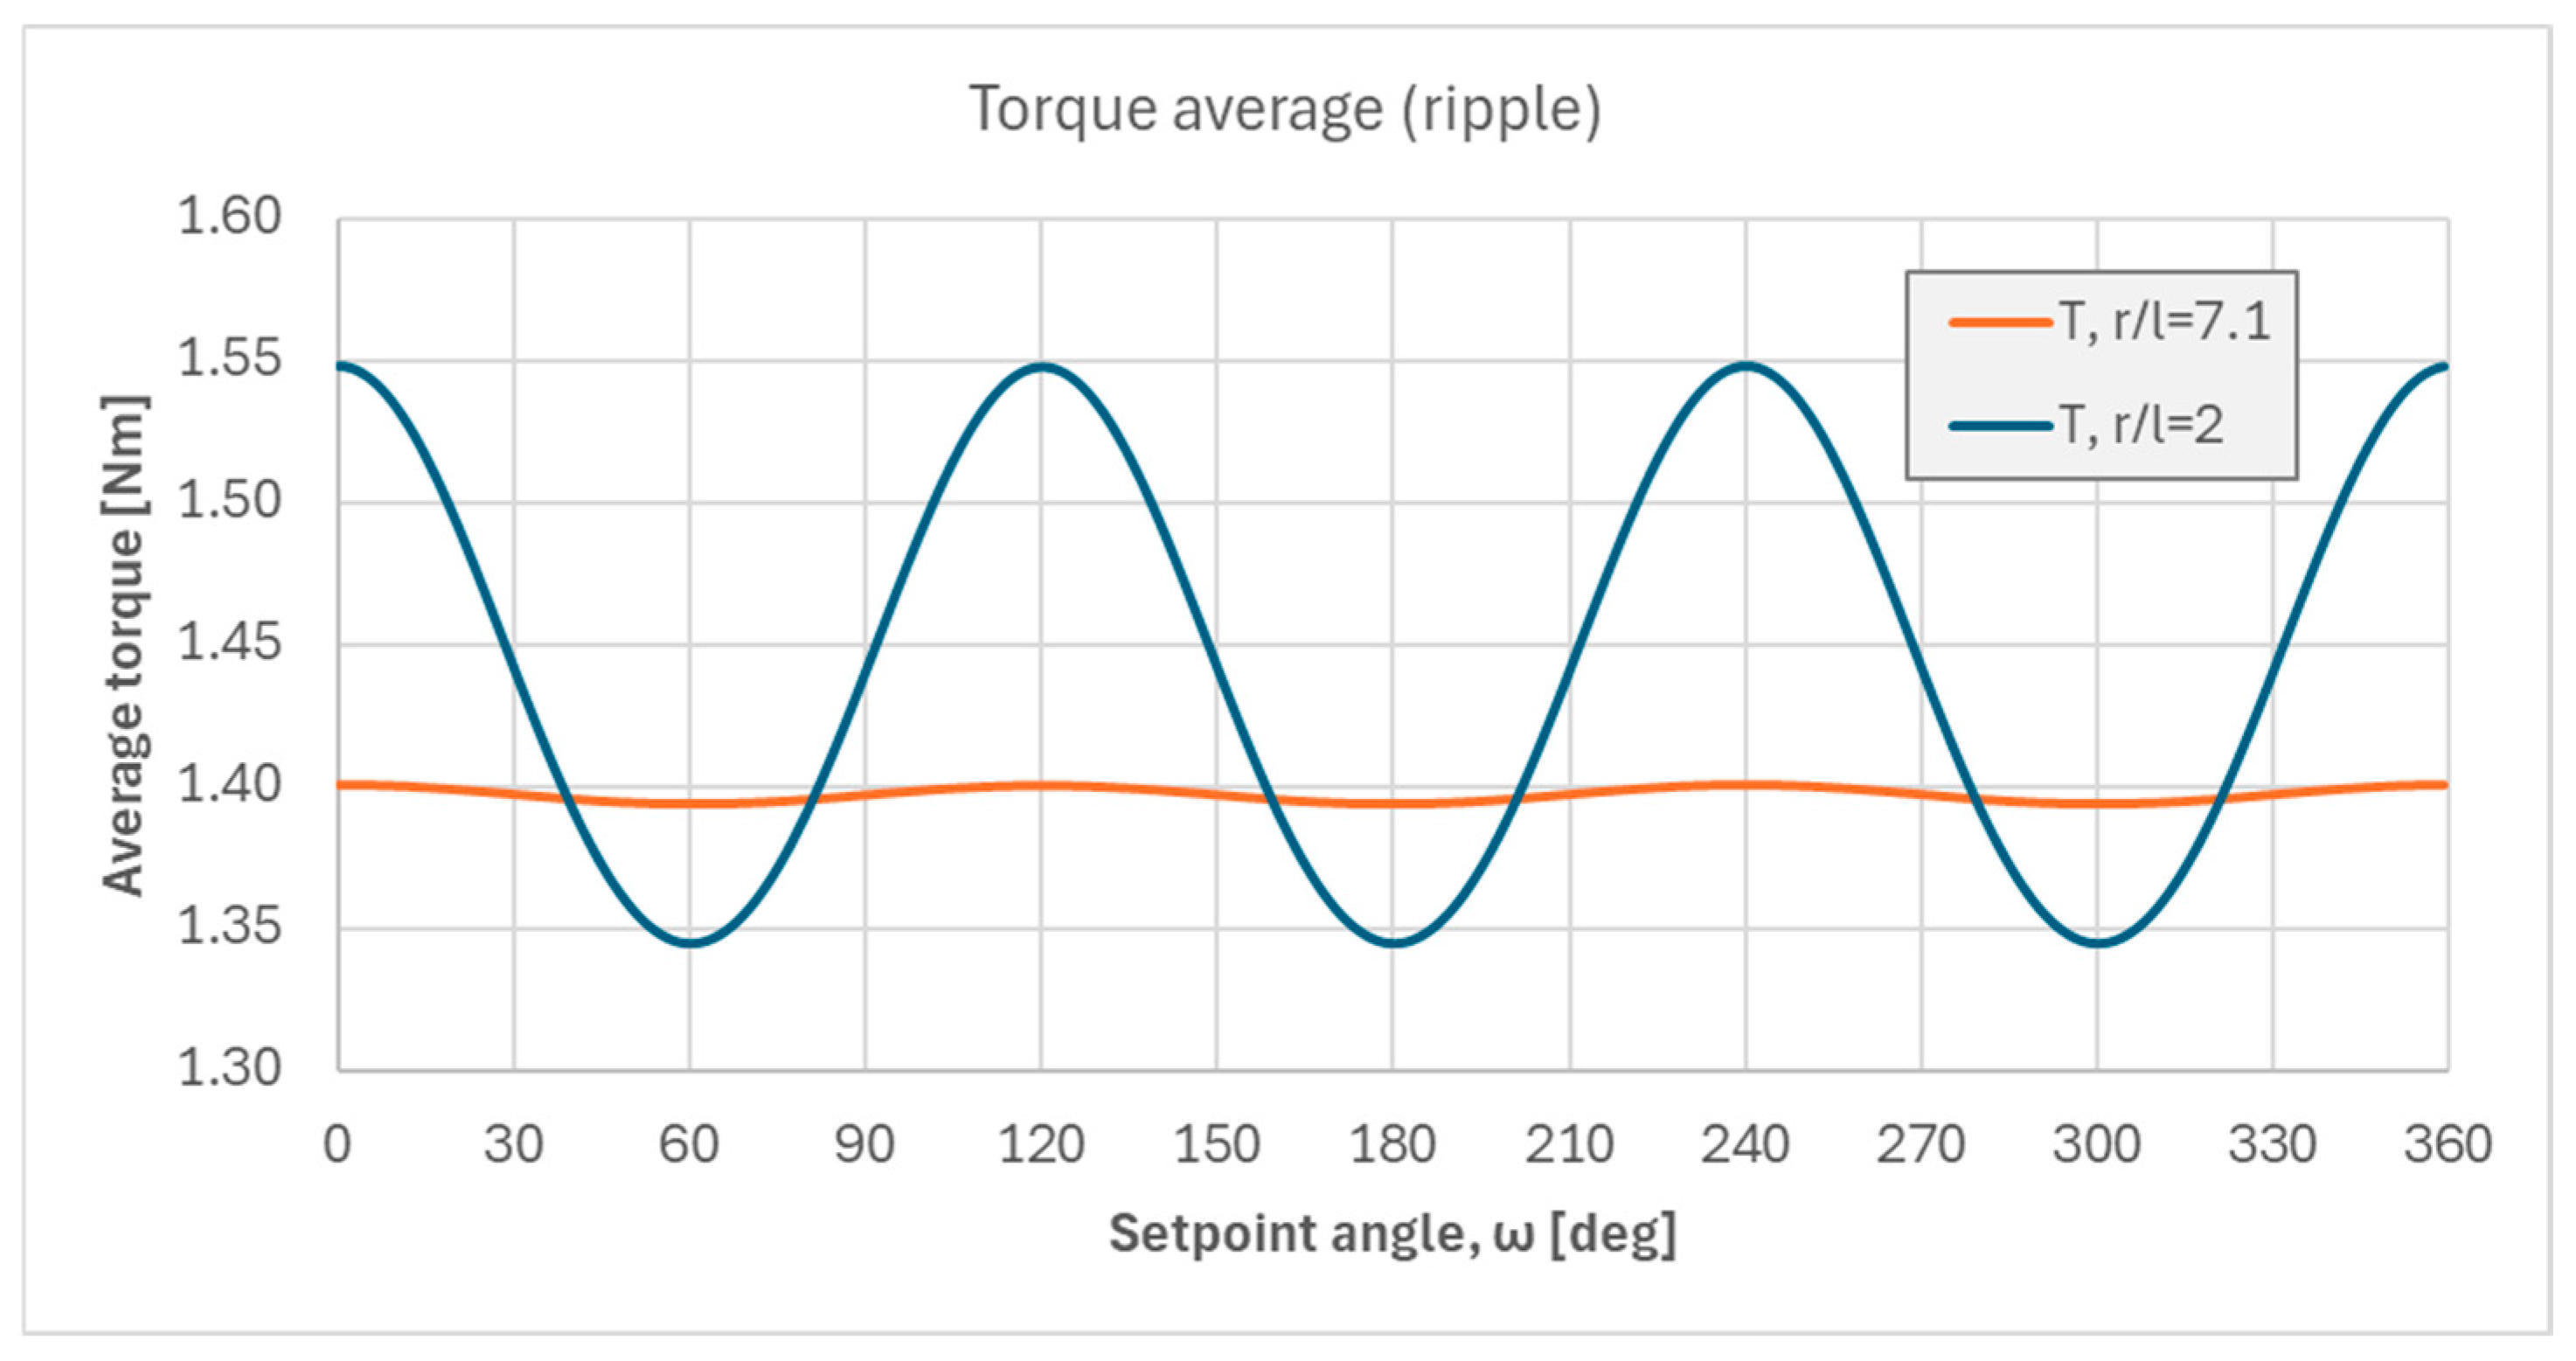
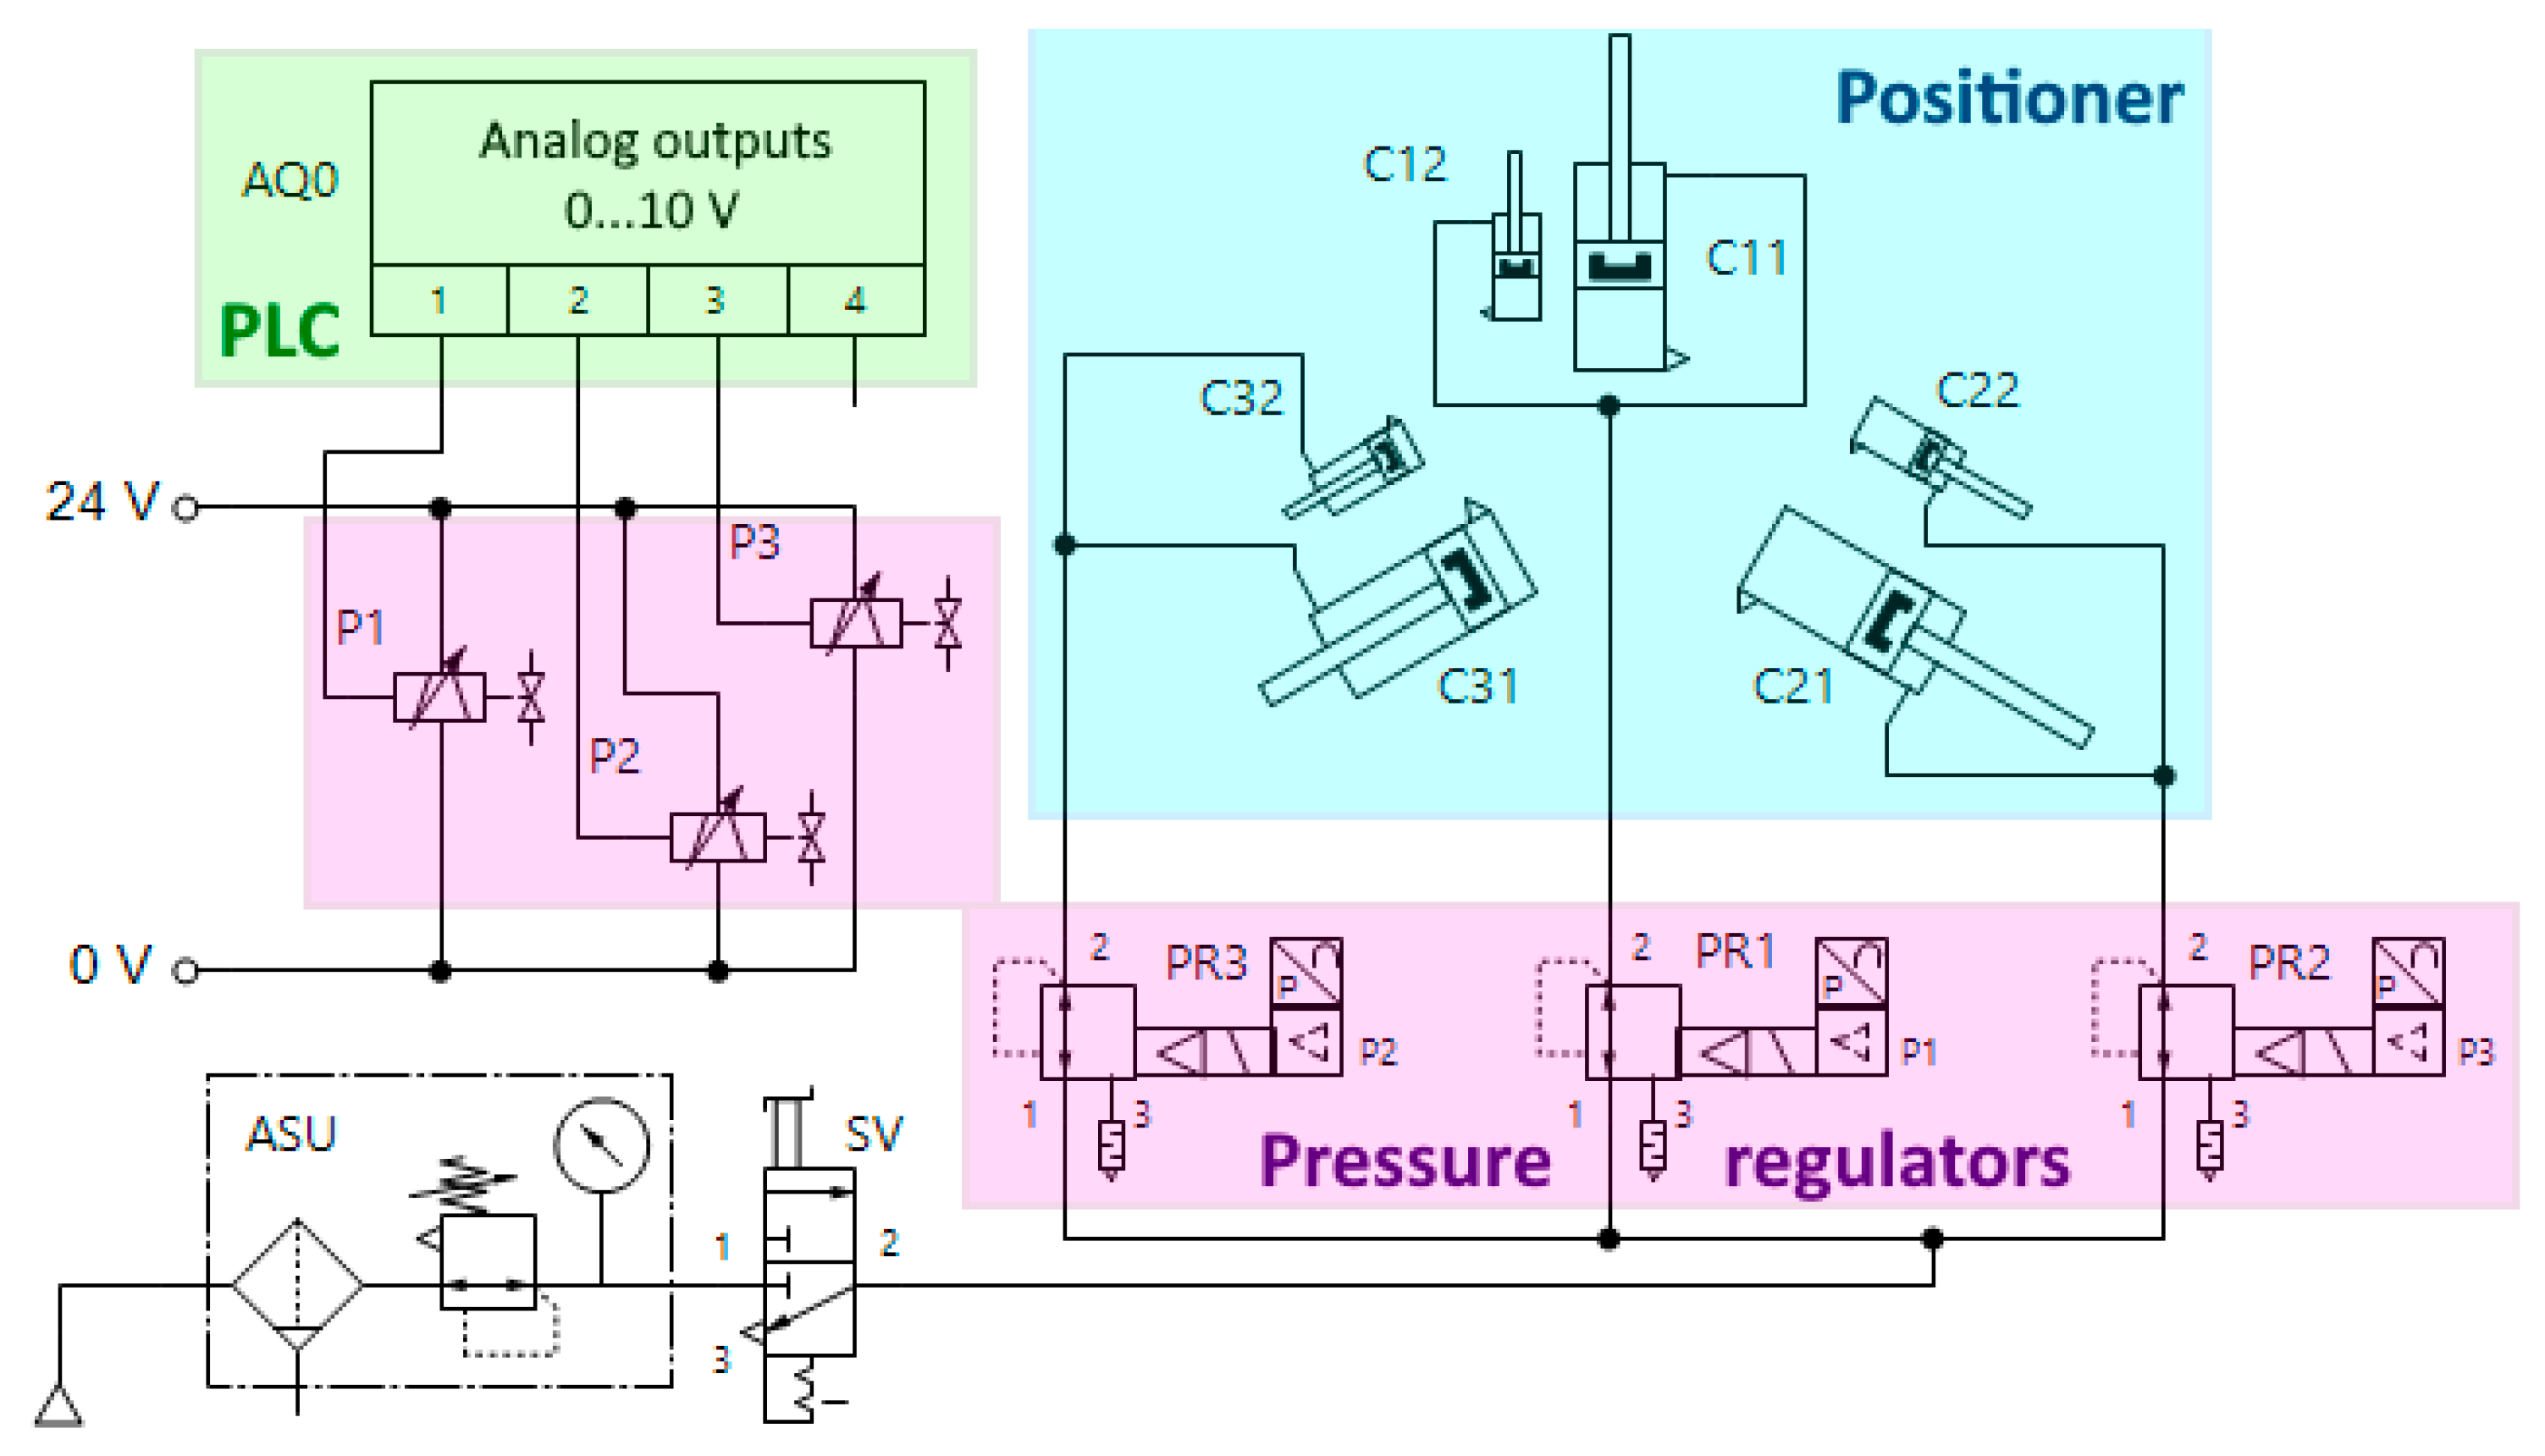
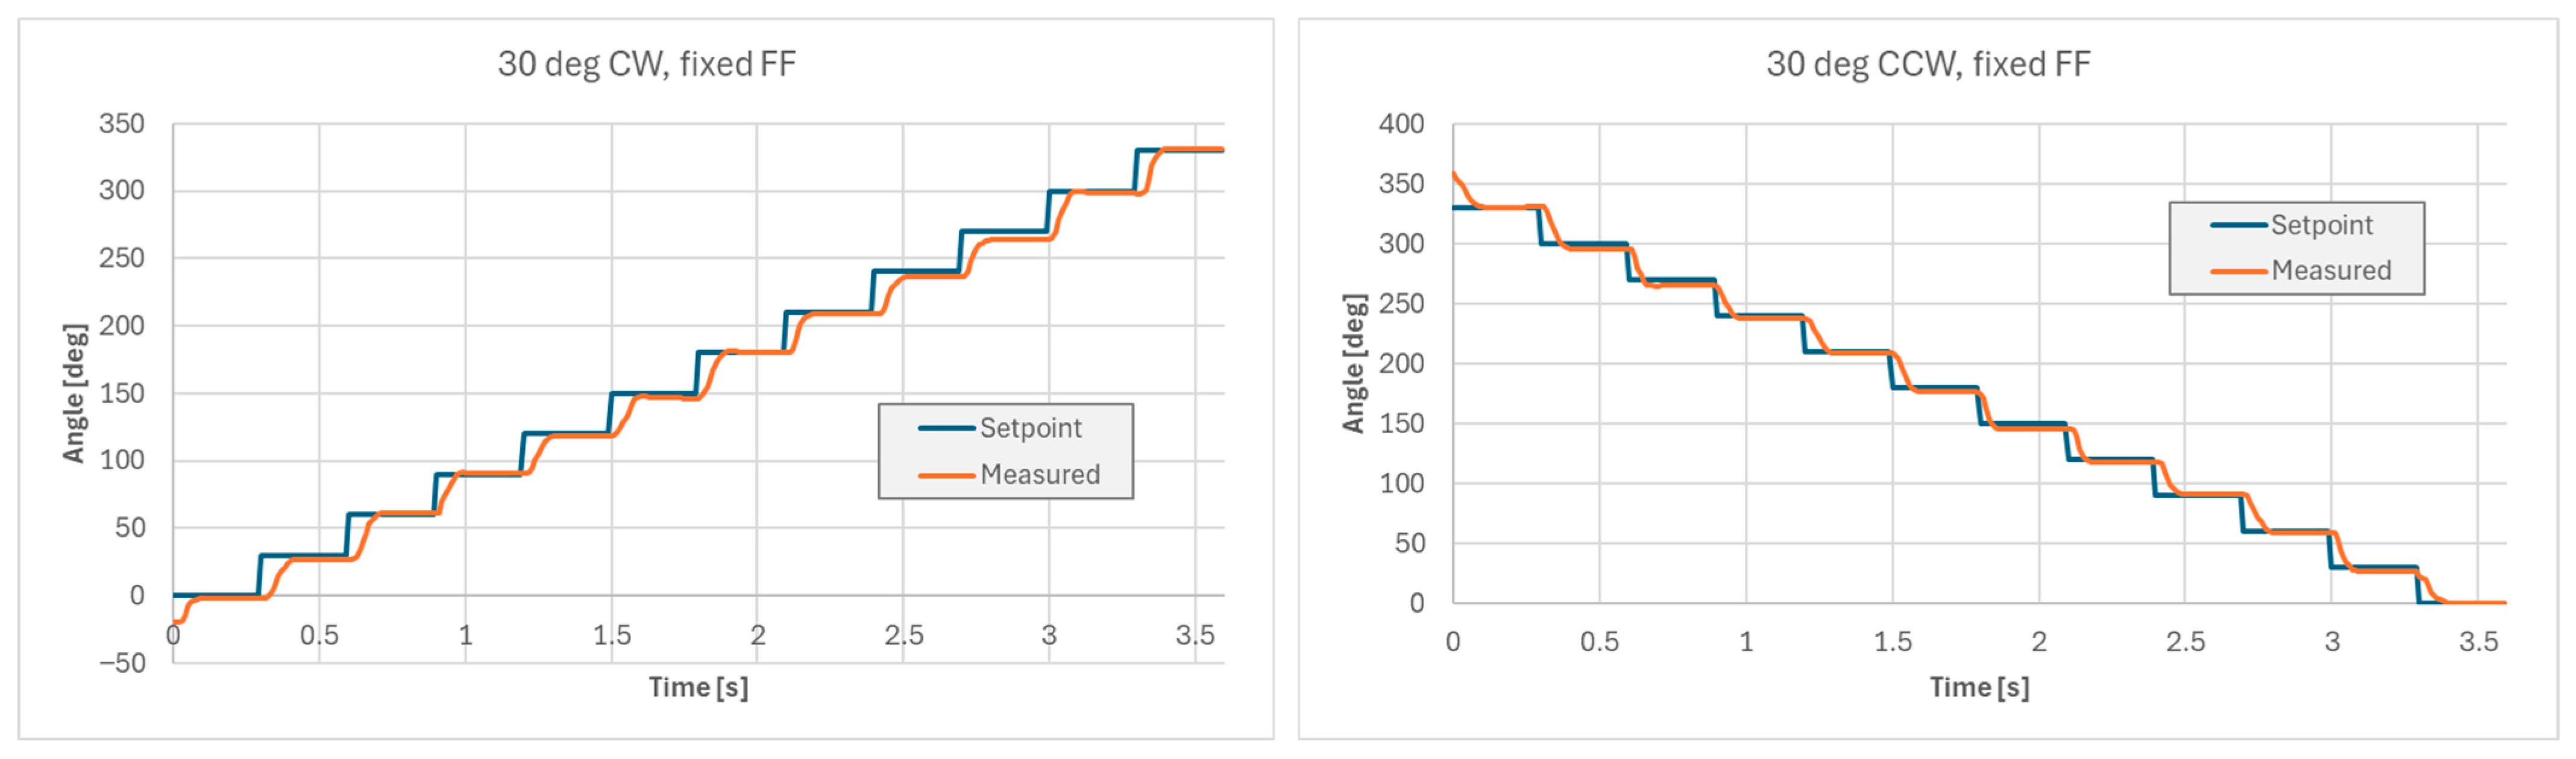
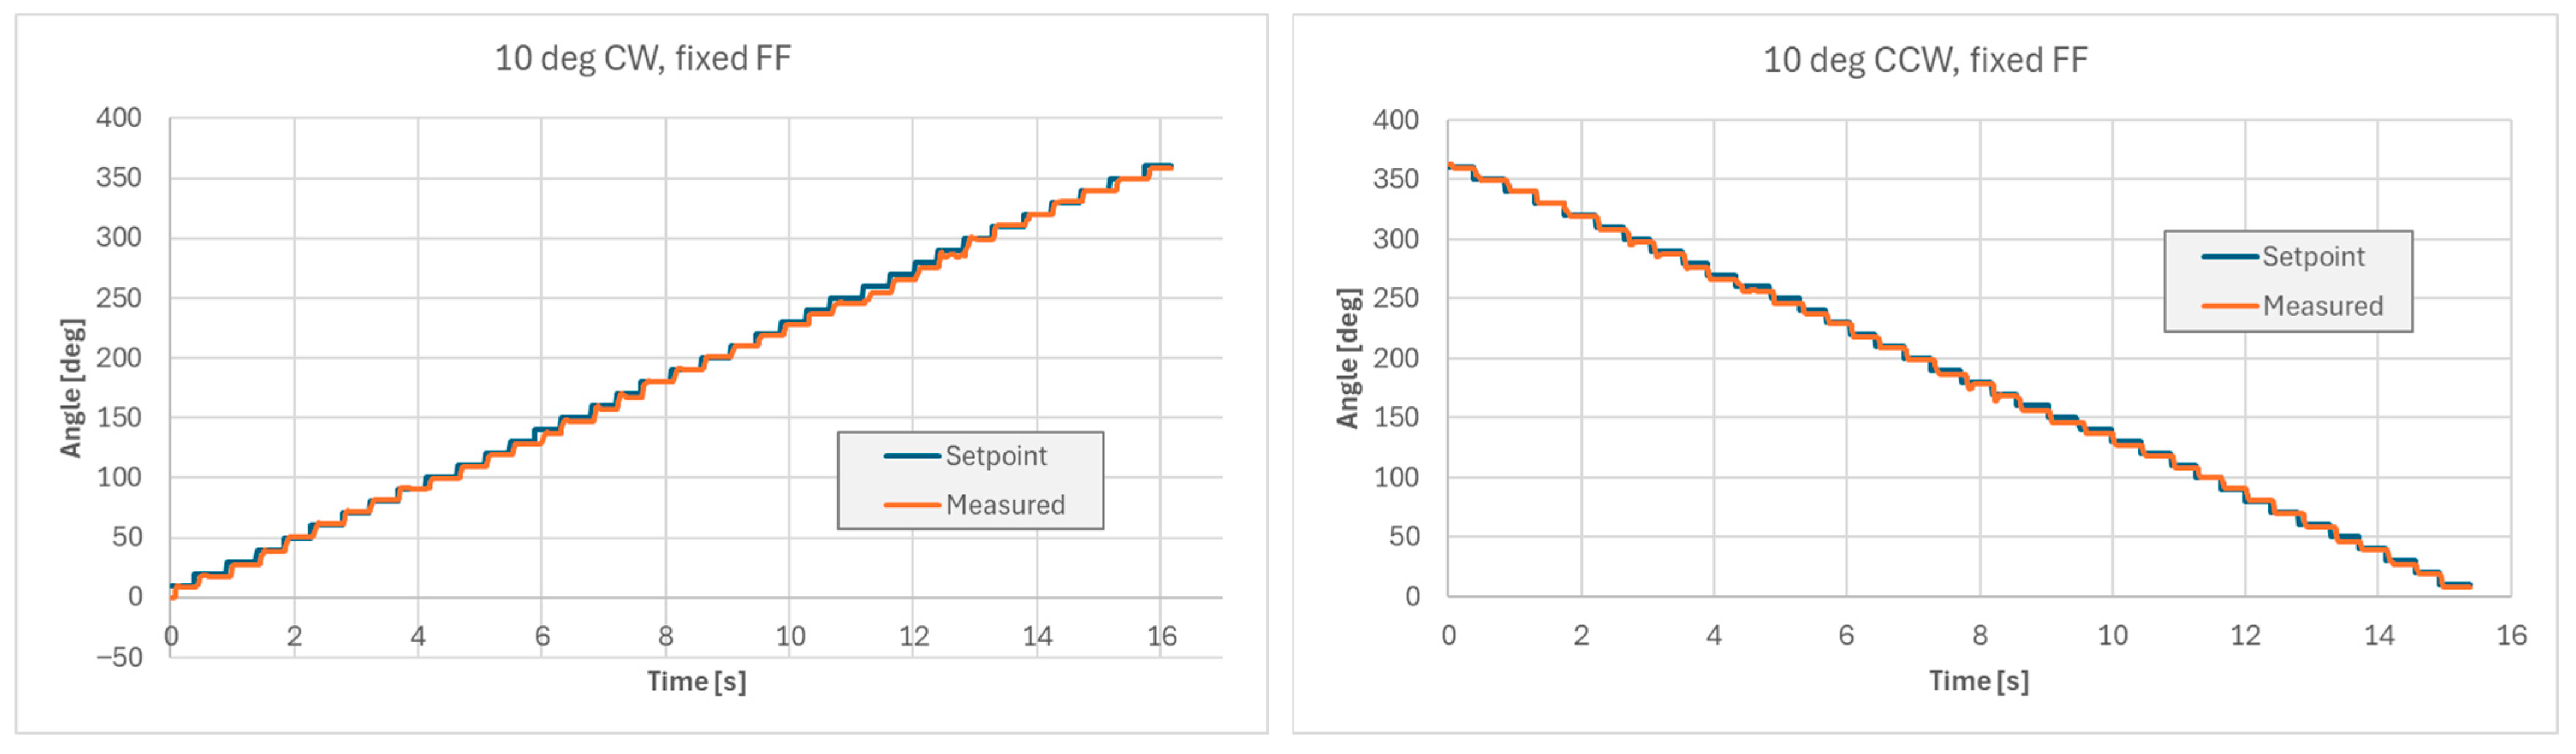
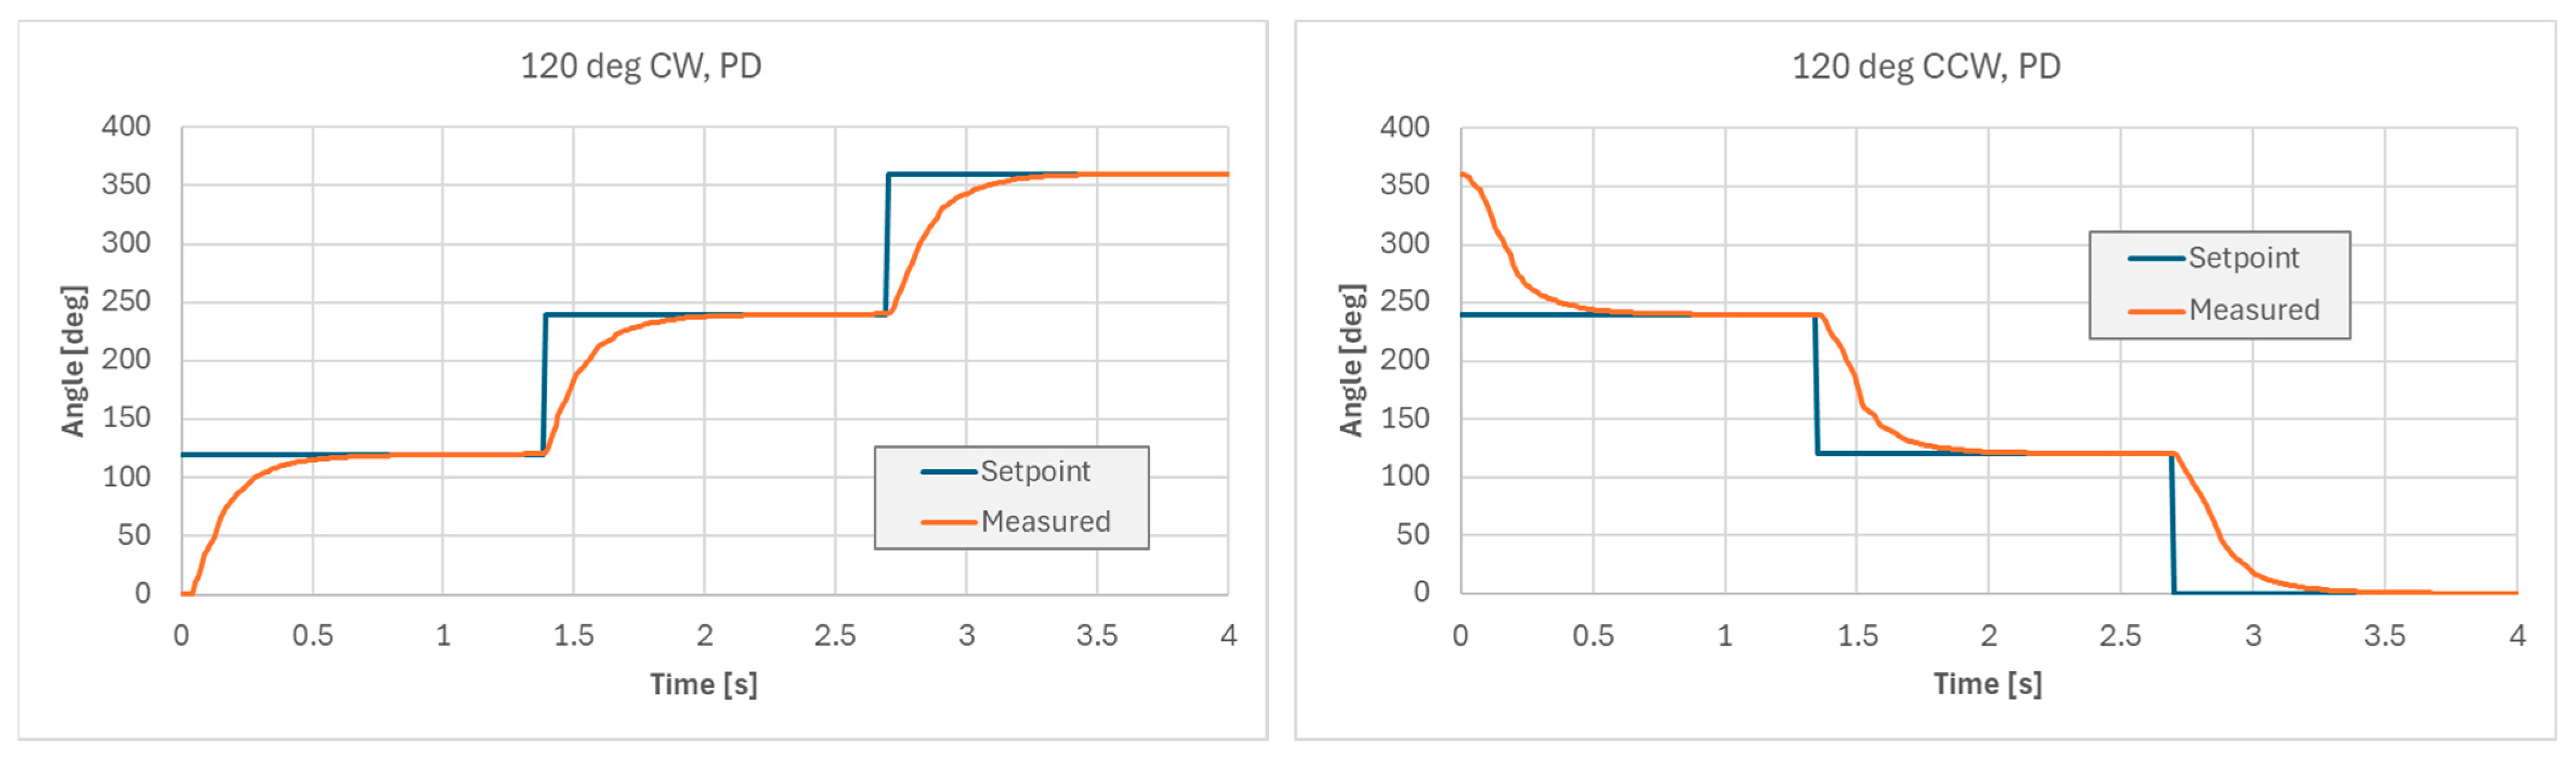
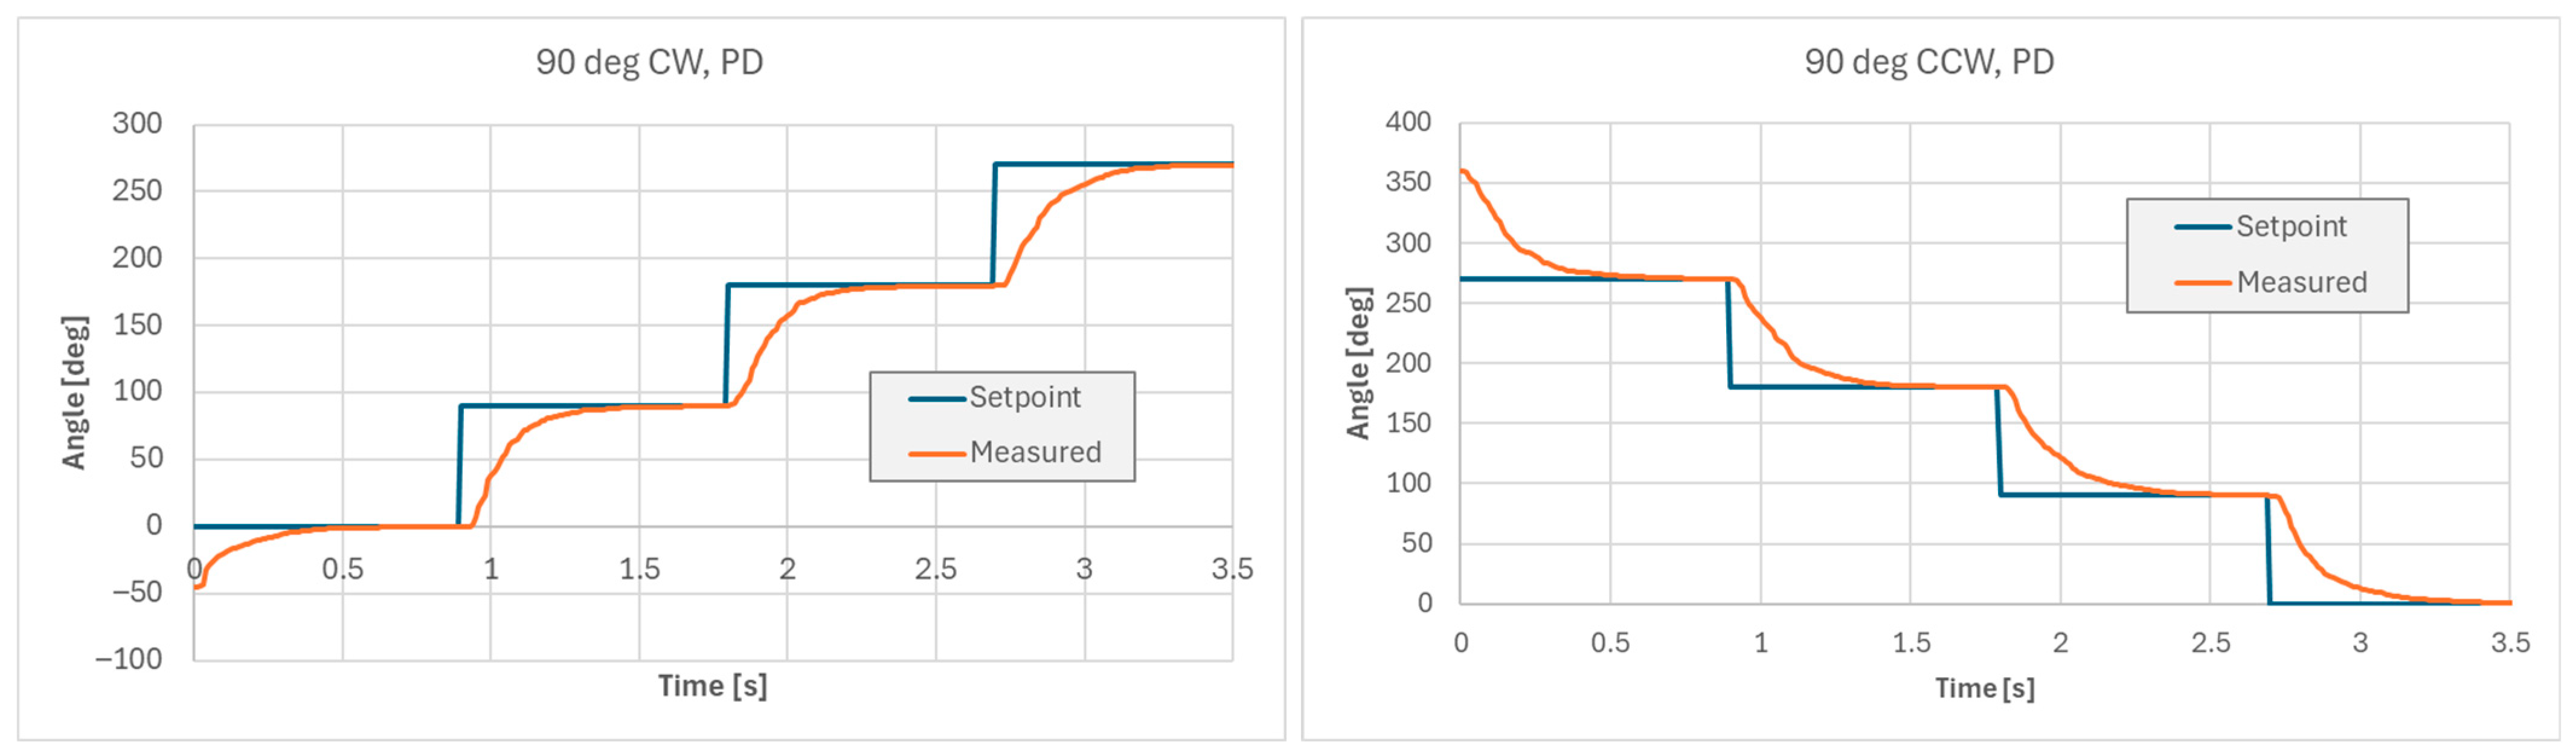
This paper presents the design, simulation, and experimental validation of a novel type of pneumatic rotary positioner that is based on a three-cylinder radial mechanism driven by independently controlled pressures. The system uses standard off-the-shelf industrial components, including pneumatic cylinders, proportional pressure regulators, and a programmable logic controller. In order to obtain angular positioning, a three-phase sinusoidal pressure commutation scheme is adopted, similar to the three-phase electrical motors. Analytical expressions for piston kinematics and torque generation are derived and used to design direct open-loop, open-loop with friction compensation, and closed-loop position control strategies. The technical implementation, with the prototype tested unloaded, can achieve accurate positioning (±3° in open-loop mode with feedforward to ±0.3° in closed-loop mode with PD controller), with very good repeatability on average (<0.5°) and smooth theoretical torque (average 1.4 Nm, with 0.51% ripple) at low speeds (<60 rpm). The experimental prototype was designed as a compact device, having approx. 94 mm diameter and 110 mm depth. When used in open-loop mode, the actuator is connected to the control system using just three pneumatic tubes and thus is completely free of any electromagnetic fields, making it suitable for some environment-critical applications. These advantages promote the proposed positioner as a practical rotary actuator in specialized automation and robotics applications where established electrical servomotors cannot be used.
Keywords: pneumatic; rotary positioner; three-phase; pressure commutation pneumatic; rotary positioner; three-phase; pressure commutation