Article

Replenishment-Aware Operation Scheduling for a Single Asphalt Crack Repair Robot

1
Institute of Engineering Construction Research, Anhui Construction Engineering Sanjian, Hefei 230031, China
2
School of Mechanical and Vehicle Engineering (School of Intelligent Manufacturing), Anhui Agricultural University, Hefei 230036, China
3
Department of Mechanical Engineering, University of Alberta, Edmonton, AB T6G 1H9, Canada
*
Author to whom correspondence should be addressed.
Buildings 2026, 16(18), 3724; https://doi.org/10.3390/buildings16183724 (registering DOI)

Submission received: 11 August 2026 / Revised: 3 September 2026 / Accepted: 11 September 2026 / Published: 19 September 2026

Abstract

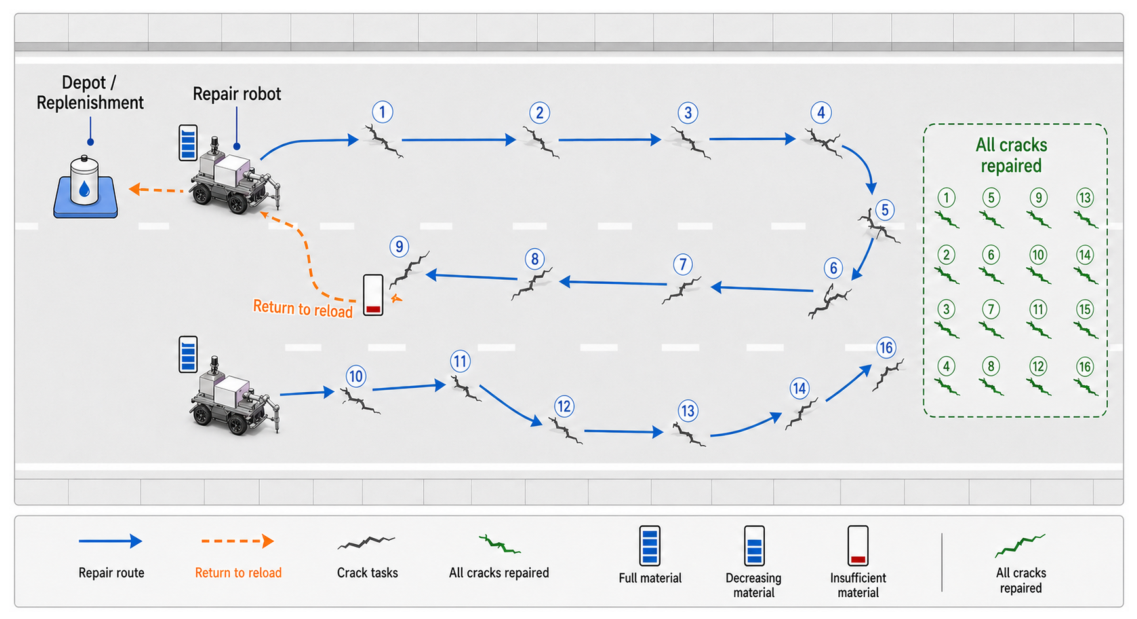
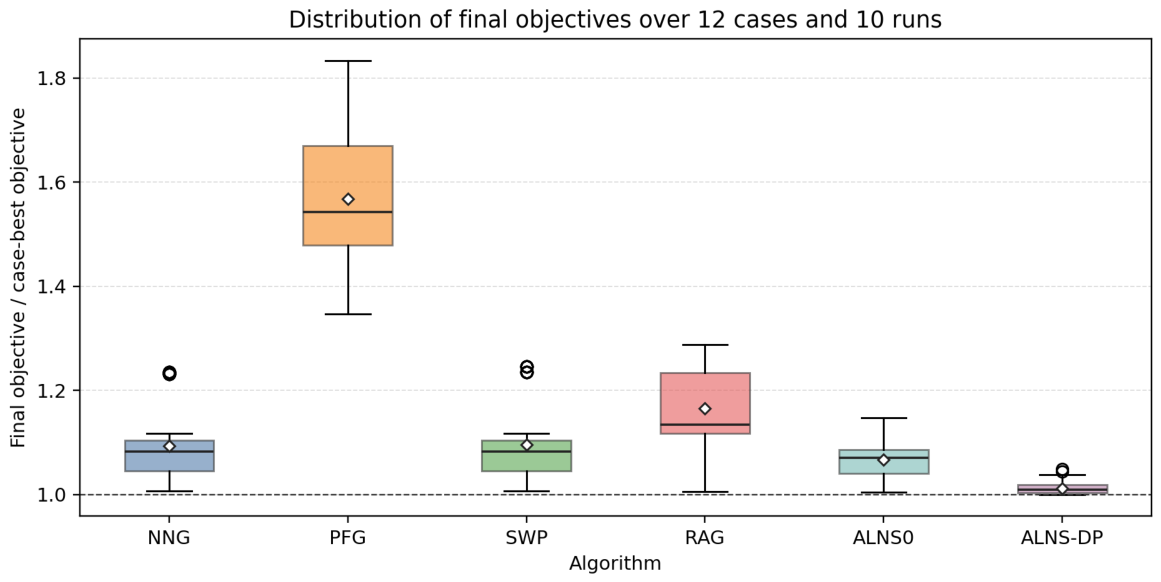
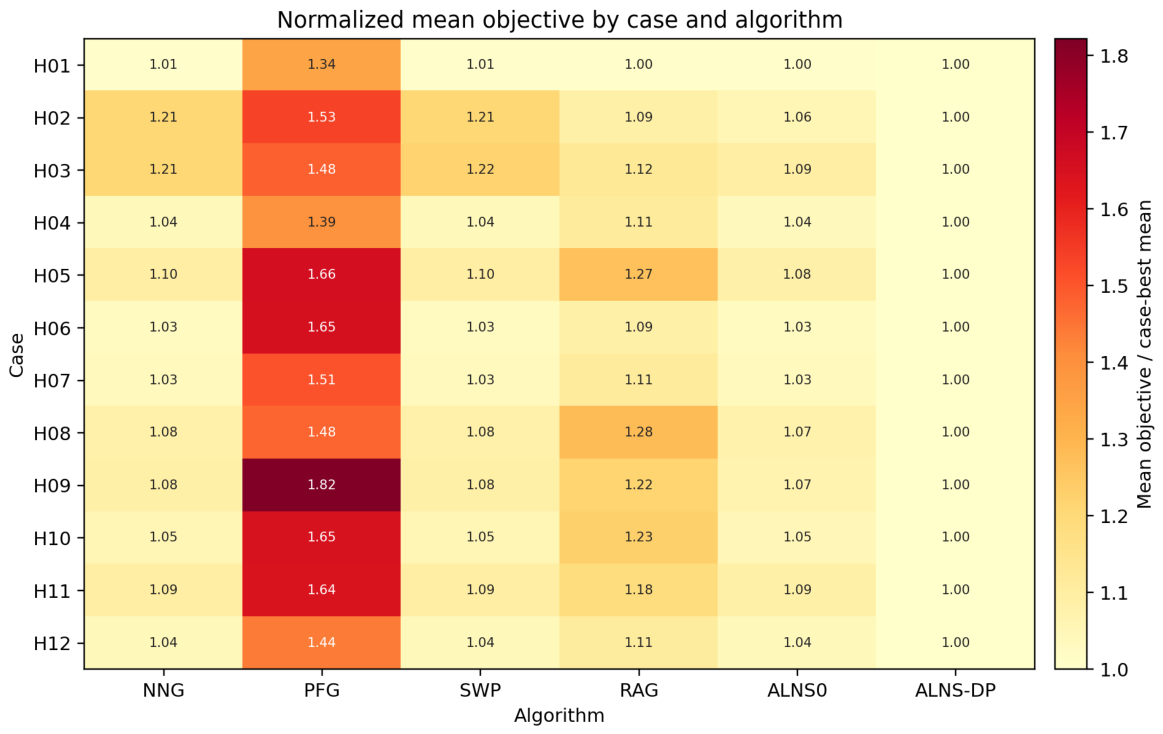
Autonomous asphalt crack repair robots can reduce workers’ exposure to traffic and improve the repeatability of pavement maintenance, but their field productivity depends on operation-level scheduling as well as crack perception and sealing control. This paper formulates a single-robot asphalt crack repair problem in which all detected cracks in an operation zone must be repaired under finite sealant capacity and explicit replenishment returns. A compact mixed-integer programming model is developed, NP-hardness is established, and an adaptive large-neighborhood search with a dynamic-programming replenishment decoder (ALNS-DP) is proposed. The method separates crack-sequence search from exact replenishment-feasible segmentation for each candidate sequence. Twelve anonymized real operation-zone cases from Hefei, China, containing 18–64 cracks are used for evaluation, and six algorithms are run ten times on every case. Compared with the strongest stochastic baseline, ALNS-DP reduces the mean final objective by 5.11% on average, with case-level reductions ranging from 0.40% to 8.52%; on the representative Case-08, the objective reduction is 6.86%. Small exact MIP benchmarks with 8–12 cracks give 0.00% optimality gaps for ALNS-DP. Additional replenishment-location, material-demand-error, ablation, scalability, and statistical tests show that the main advantage comes from coupling sequence search with replenishment-aware decoding rather than from omitting difficult cracks.
Keywords: asphalt pavement; crack repair robot; operation scheduling; material replenishment; adaptive large-neighborhood search; dynamic programming; pavement maintenance asphalt pavement; crack repair robot; operation scheduling; material replenishment; adaptive large-neighborhood search; dynamic programming; pavement maintenance